Error Analysis and Drive Optimization of a Minimally Invasive Surgical Robot

Abstract
1. Introduction
2. Materials and Methods
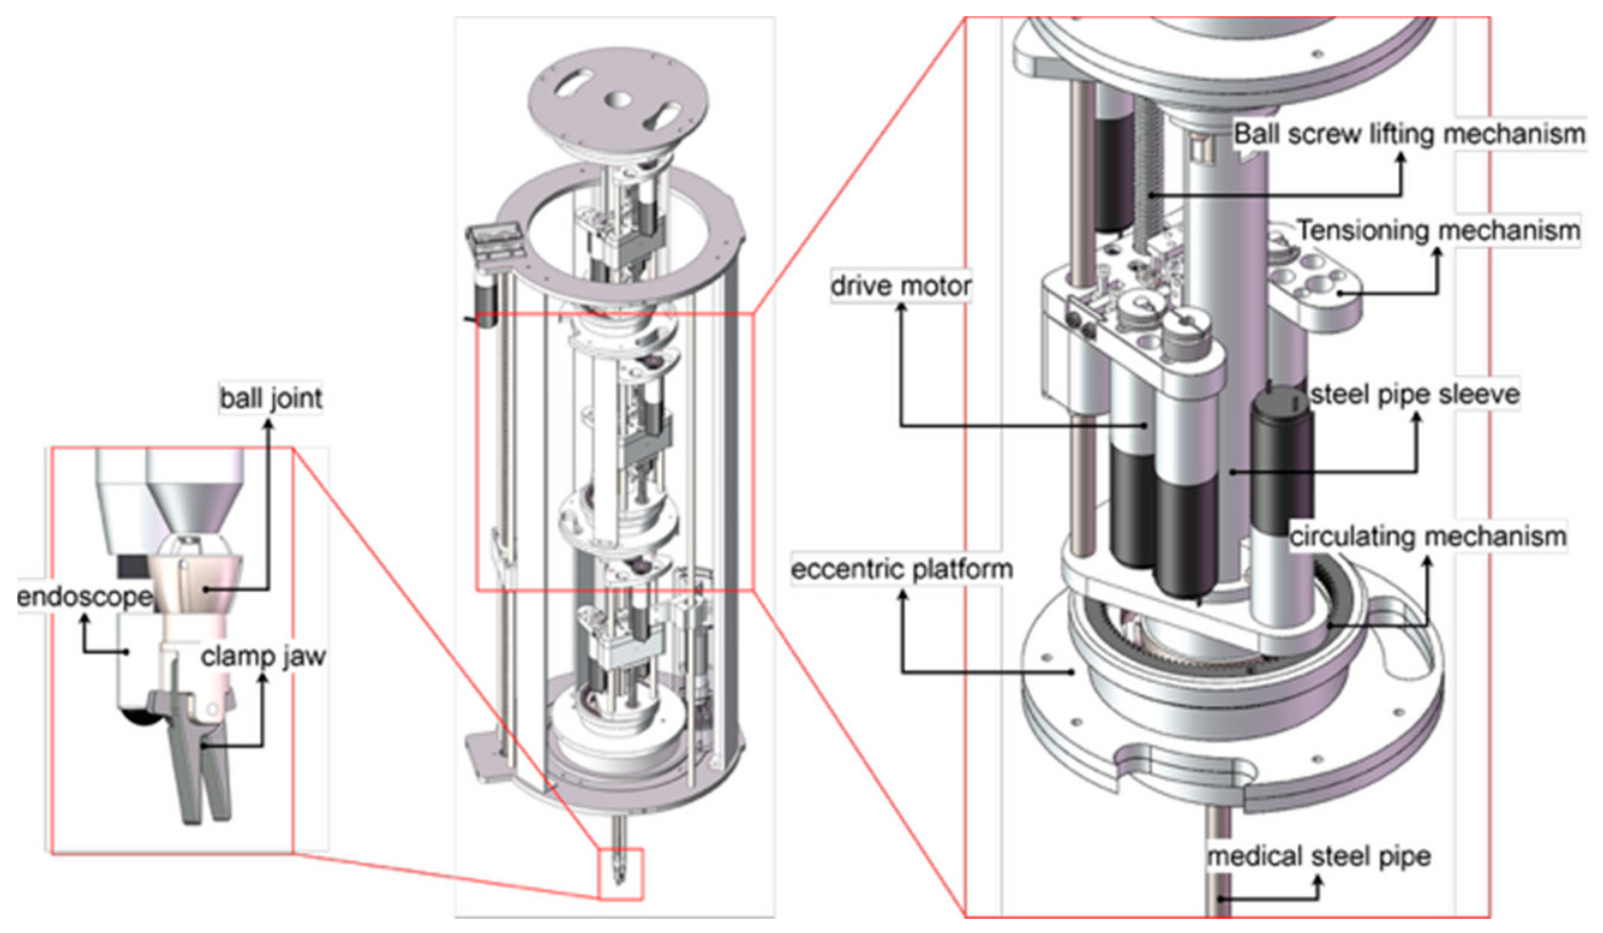
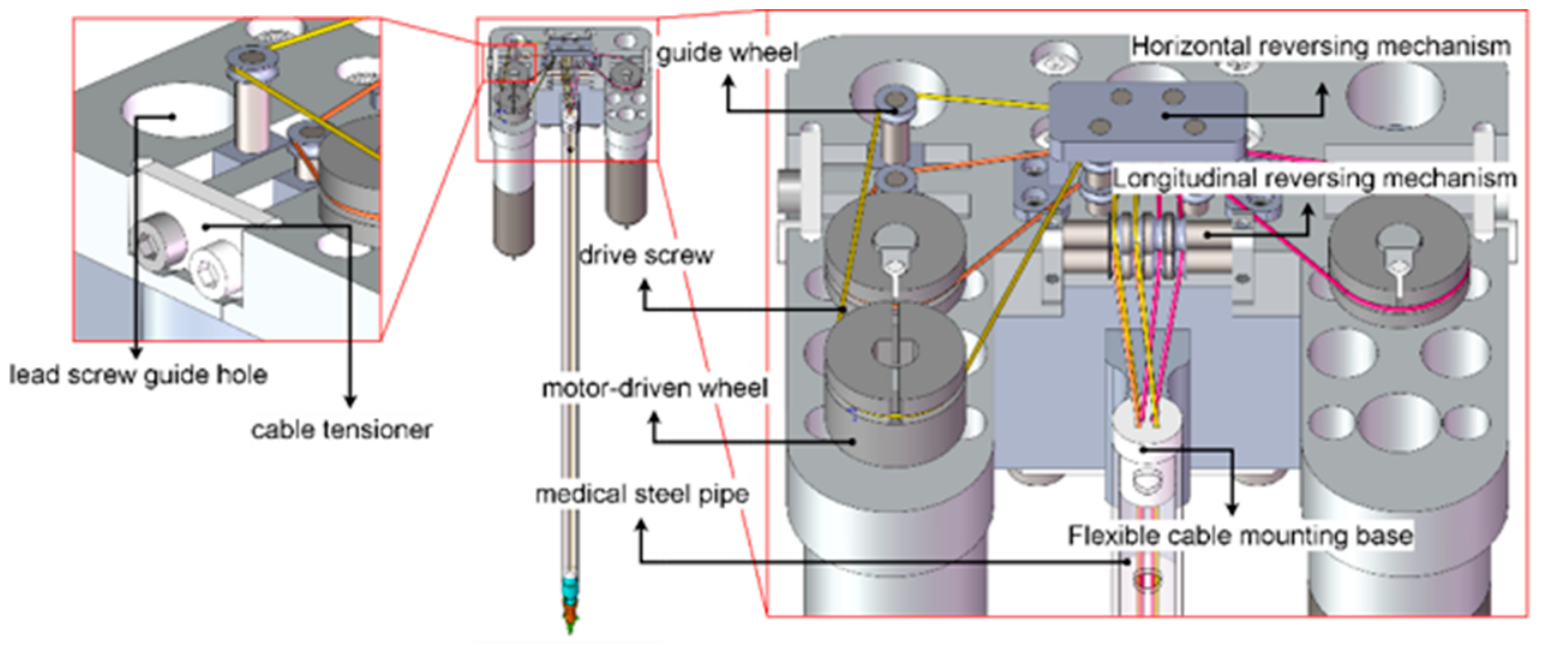
2.1. Structure of the Minimally Invasive Surgical Robot
2.2. System Issues and Modeling
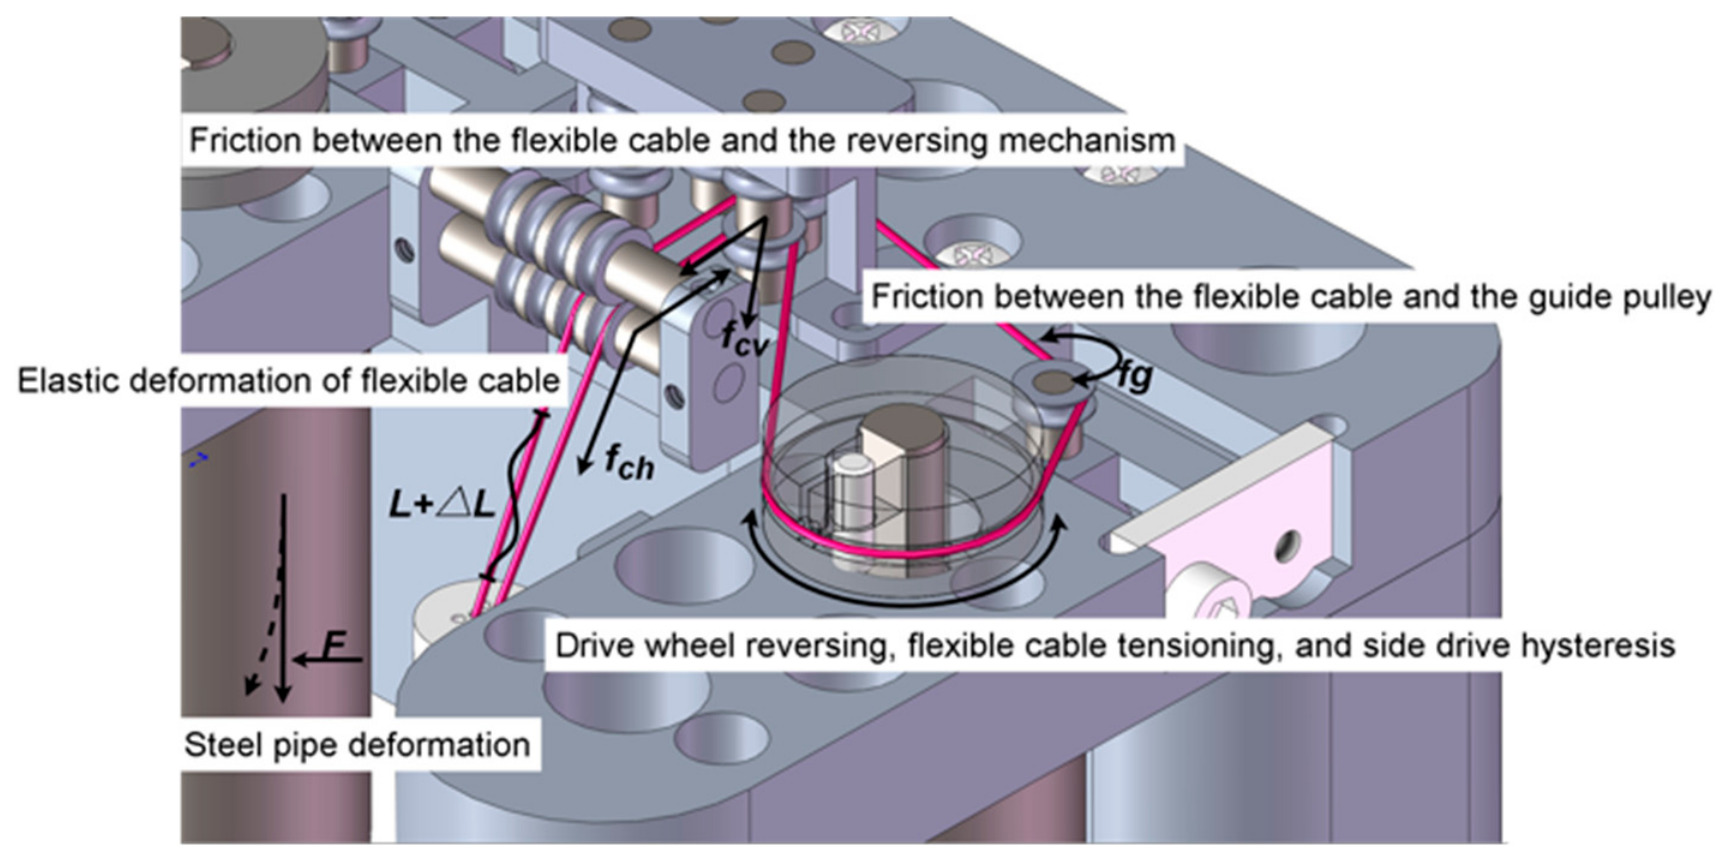
2.2.1. Error Sources in the Minimally Invasive Surgical Robot System
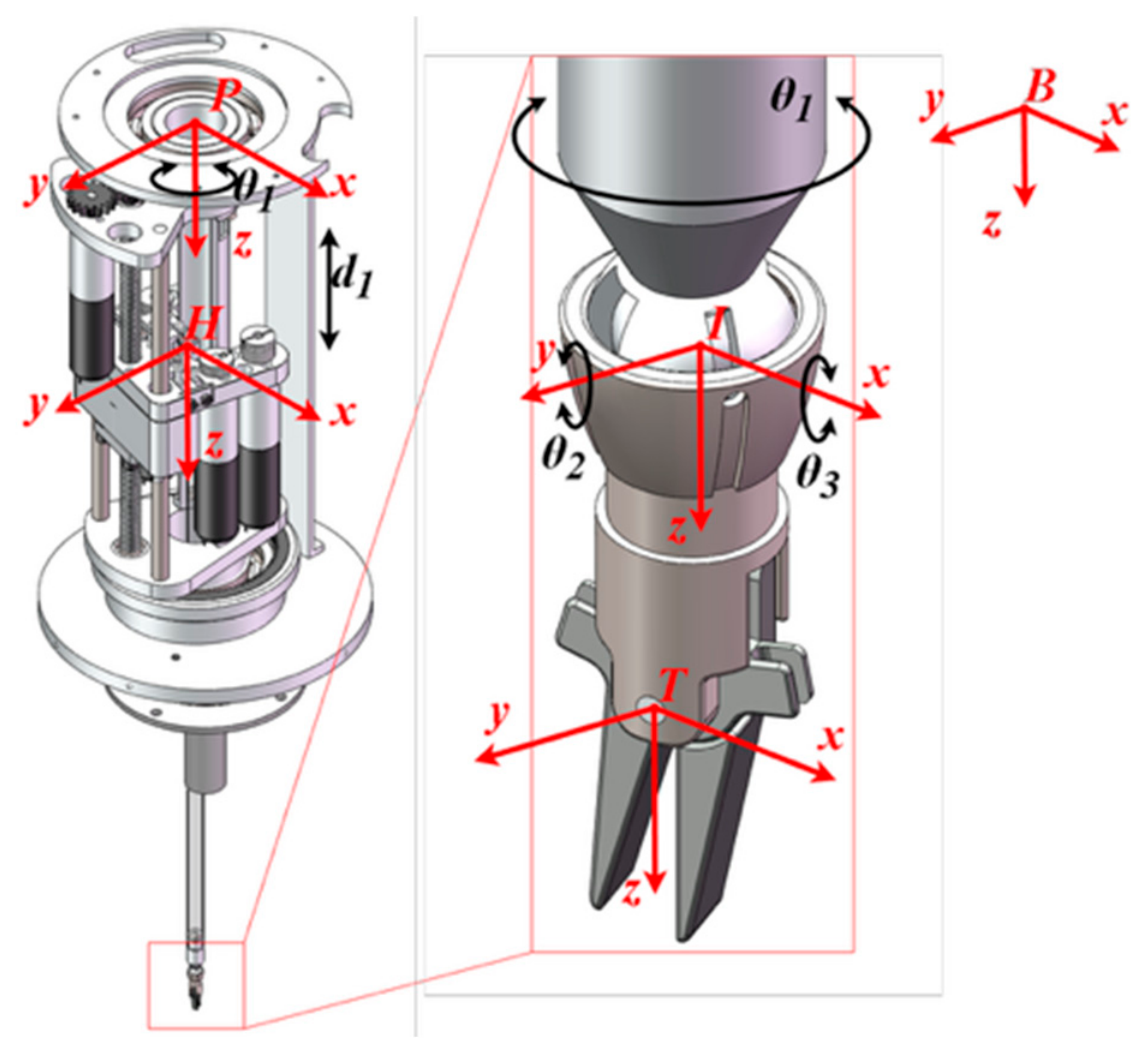
2.2.2. Kinematic Modeling of the Minimally Invasive Surgical Robot
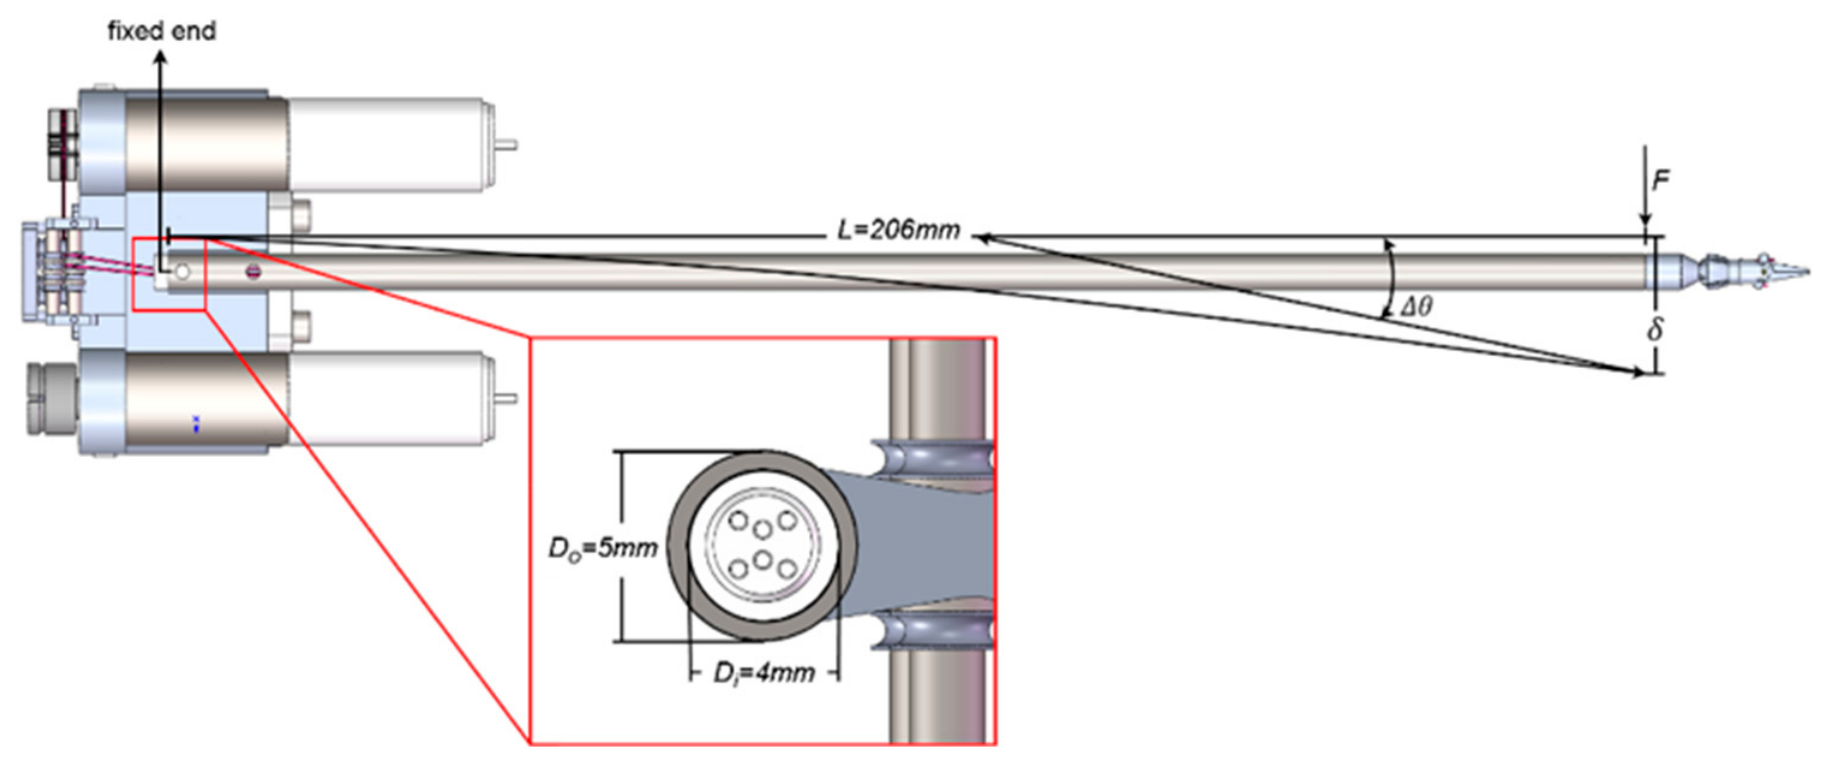
2.2.3. Structural Deflection Modeling
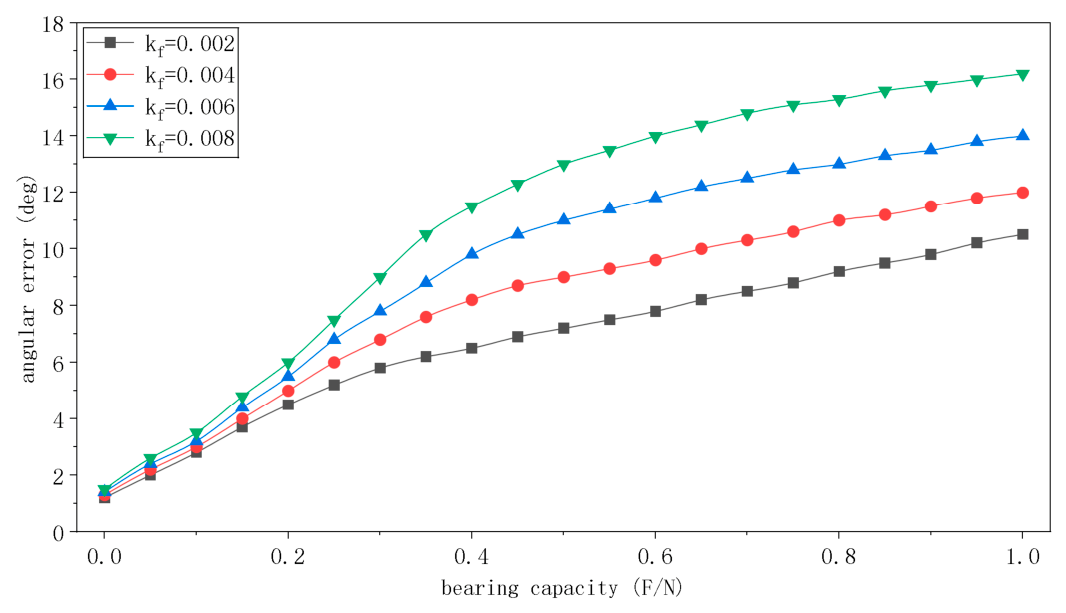
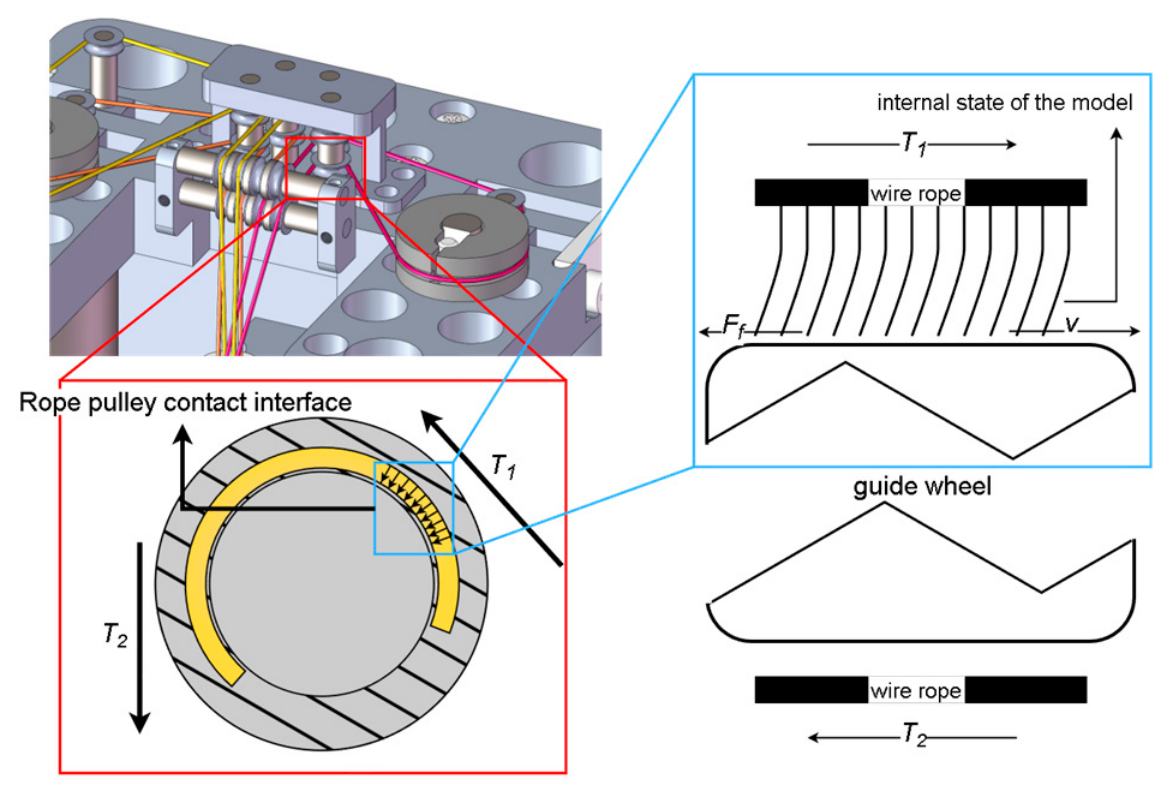
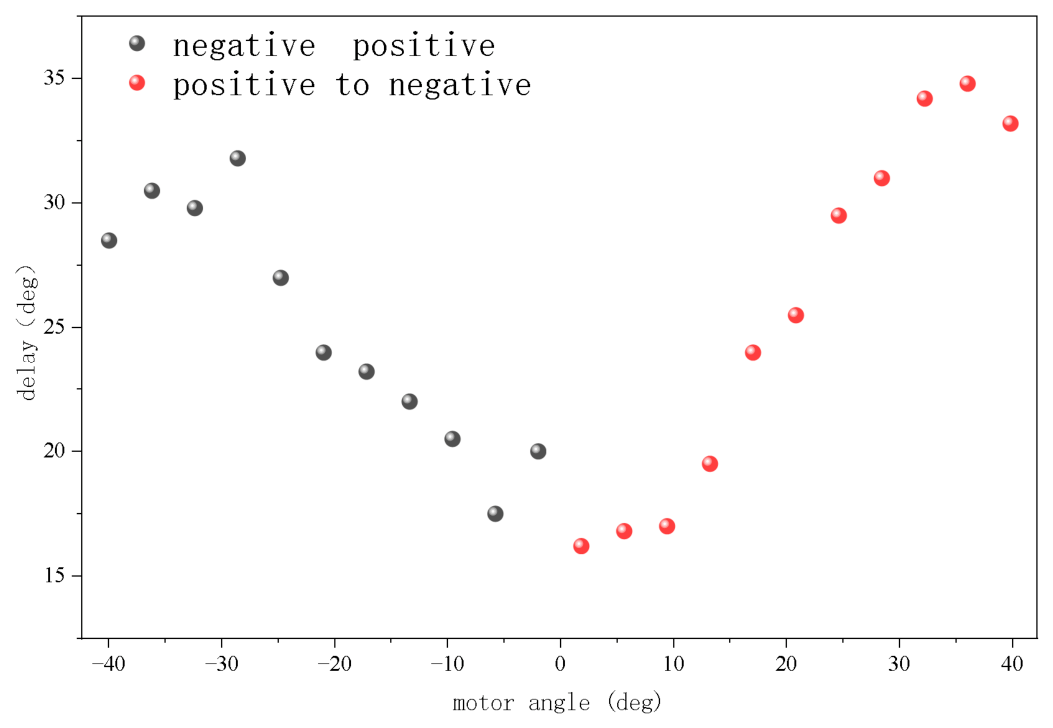
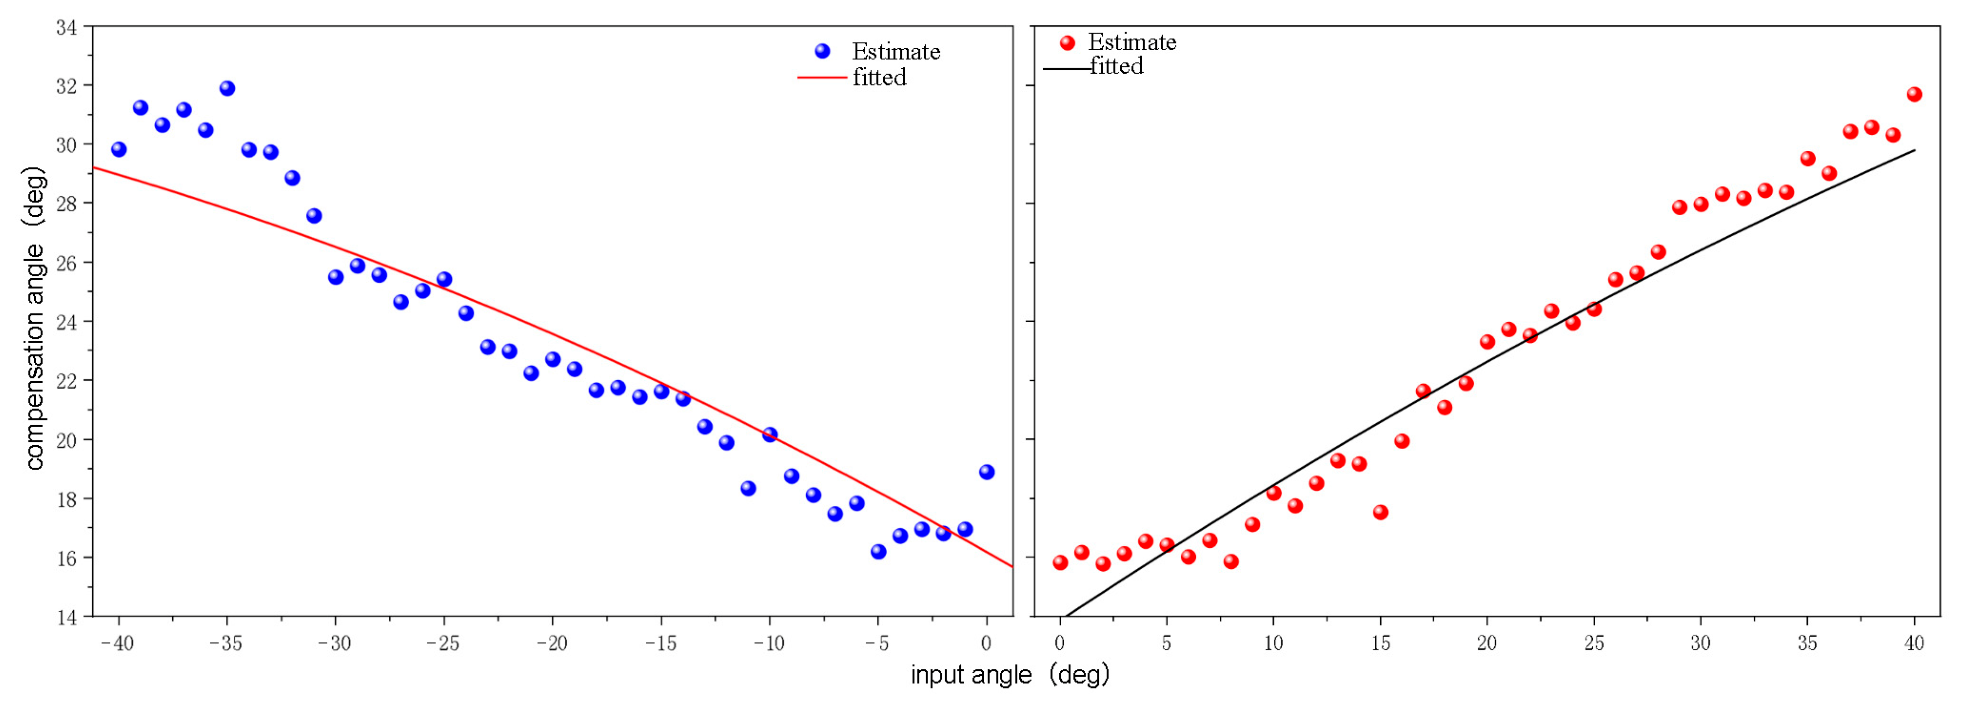
2.2.4. Establishment of the LuGre Friction Model for Cable-Driven Systems
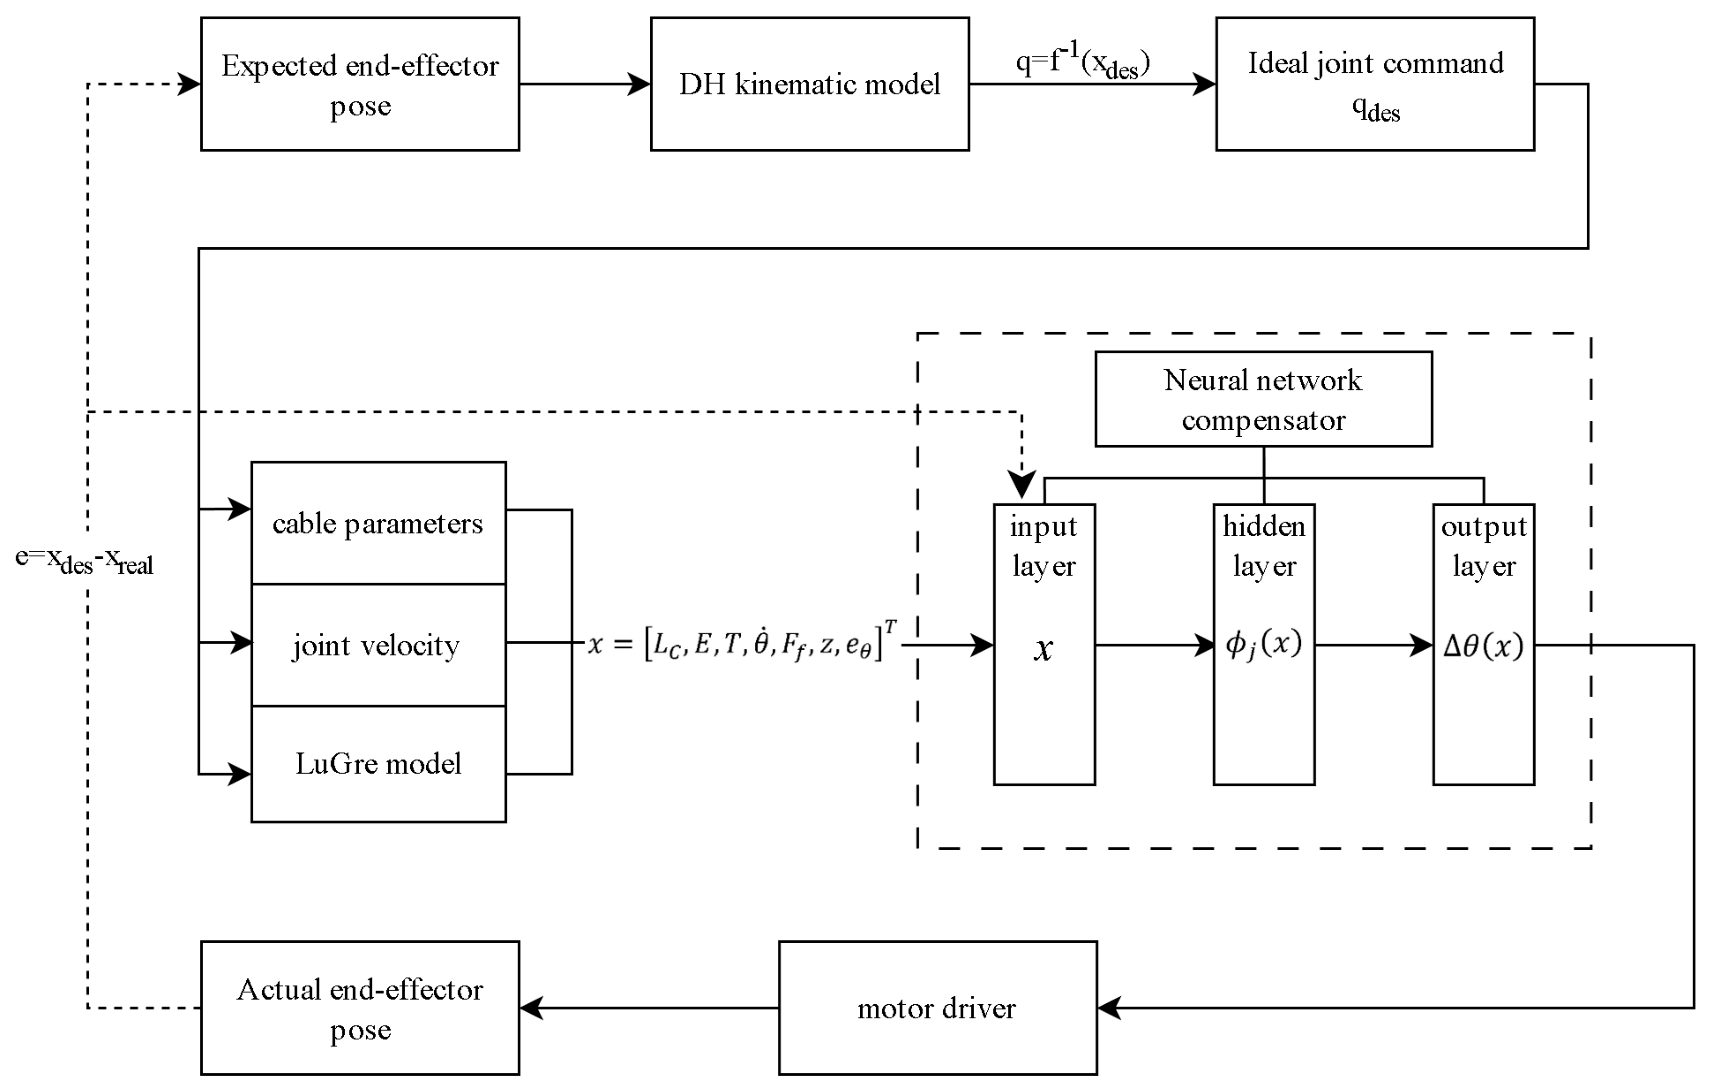
2.3. DH Parameter Identification and Neural Network Compensation
2.3.1. Identification of DH Error Parameters
2.3.2. Feedforward Neural Network Compensation
3. Results
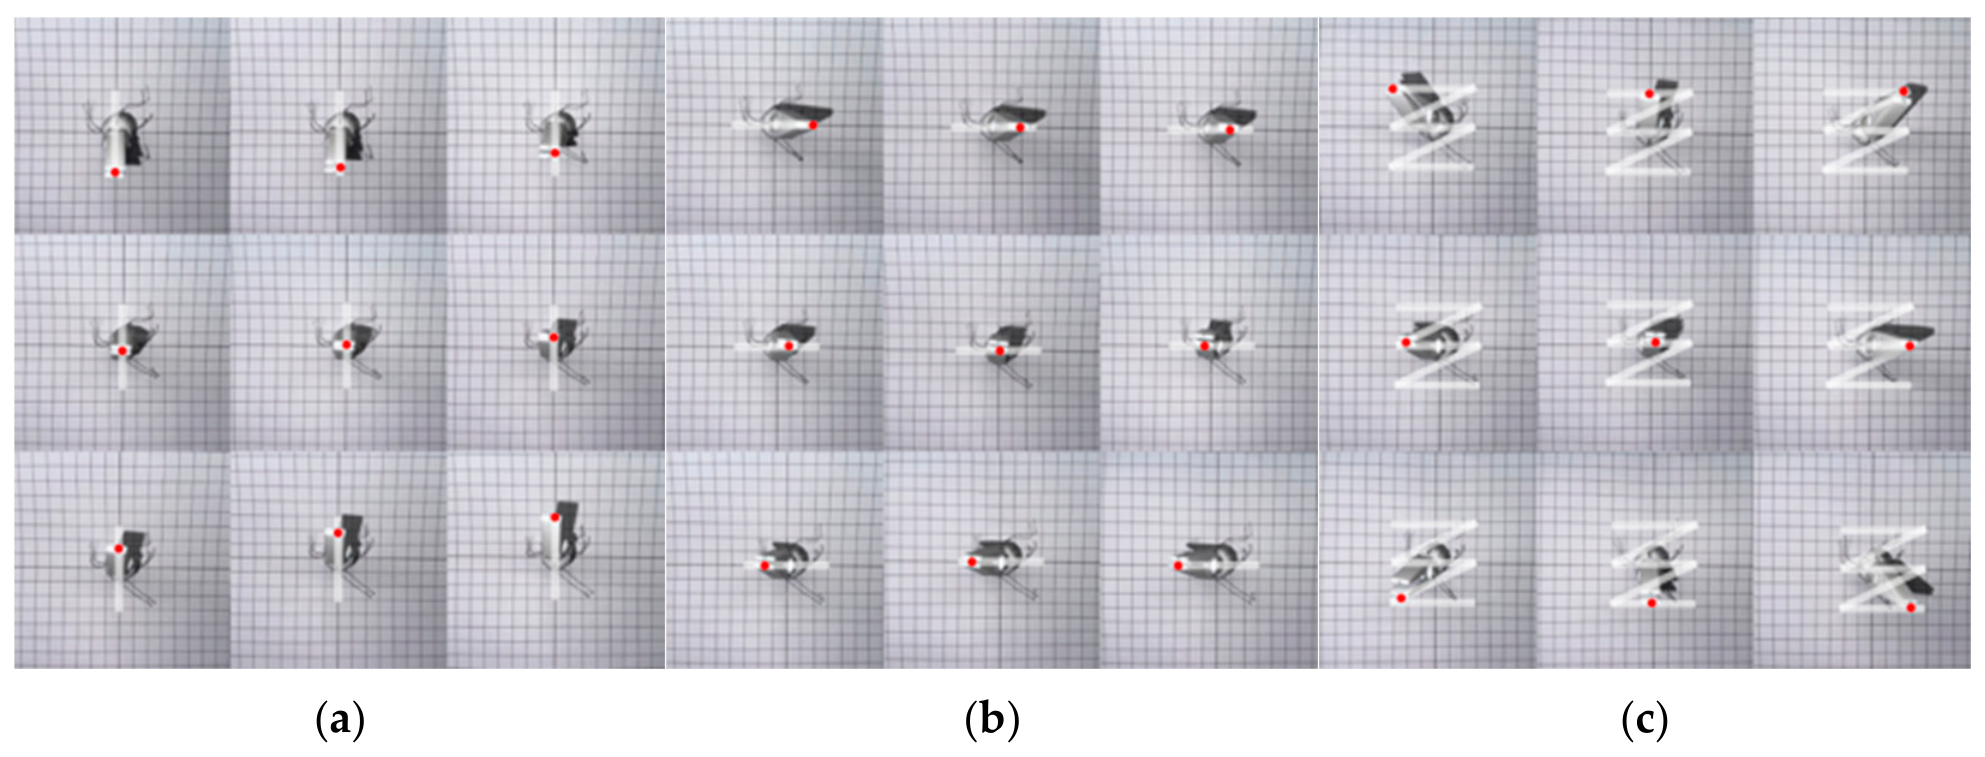
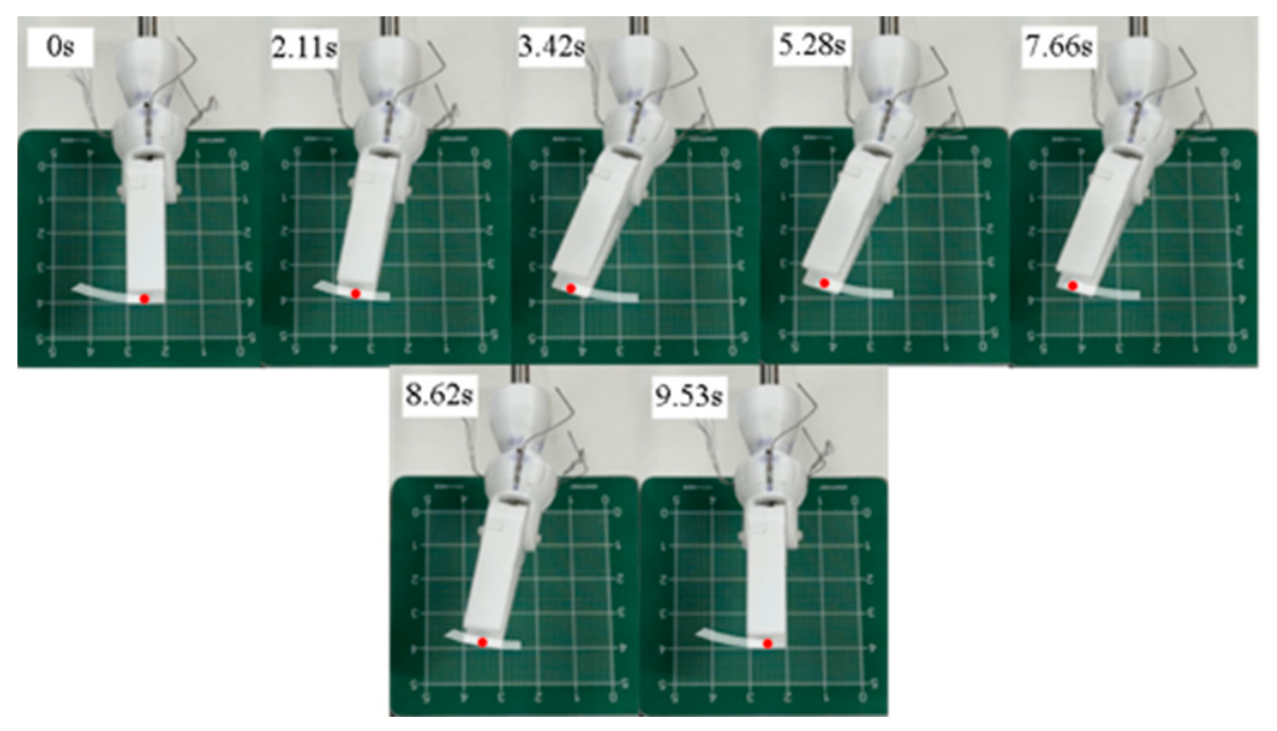
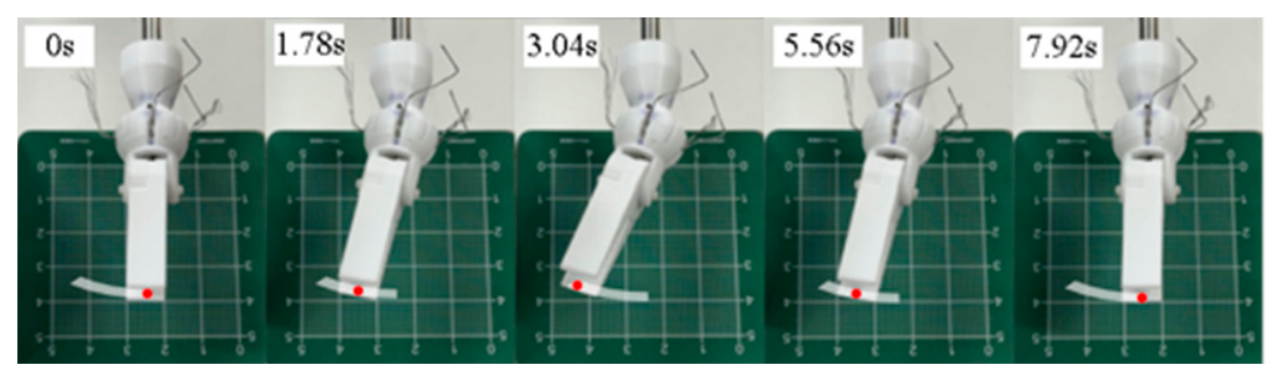
3.1. Comparative Error Experiments
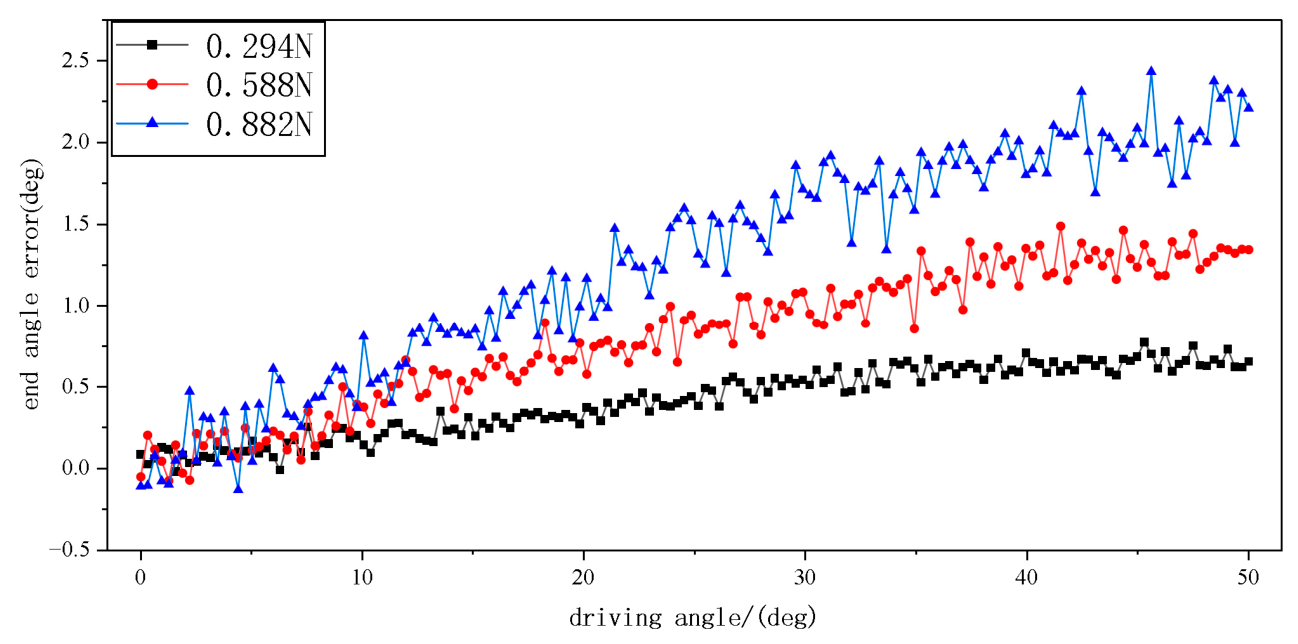
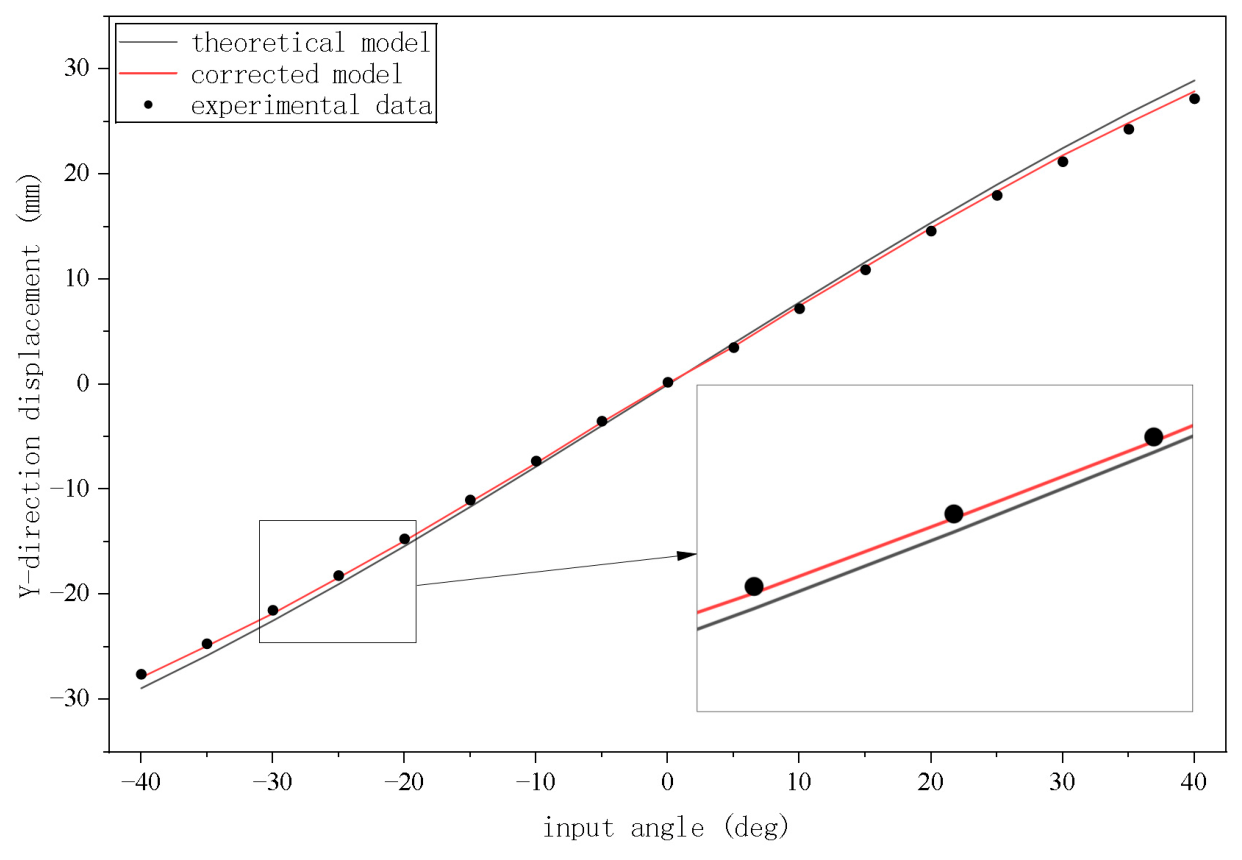
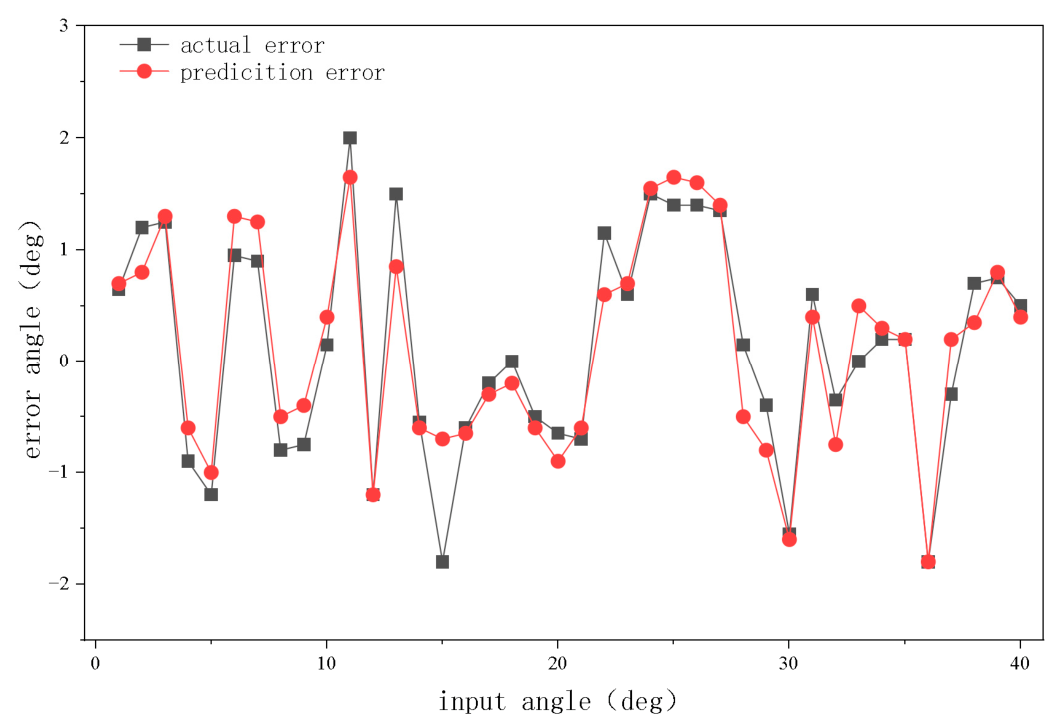
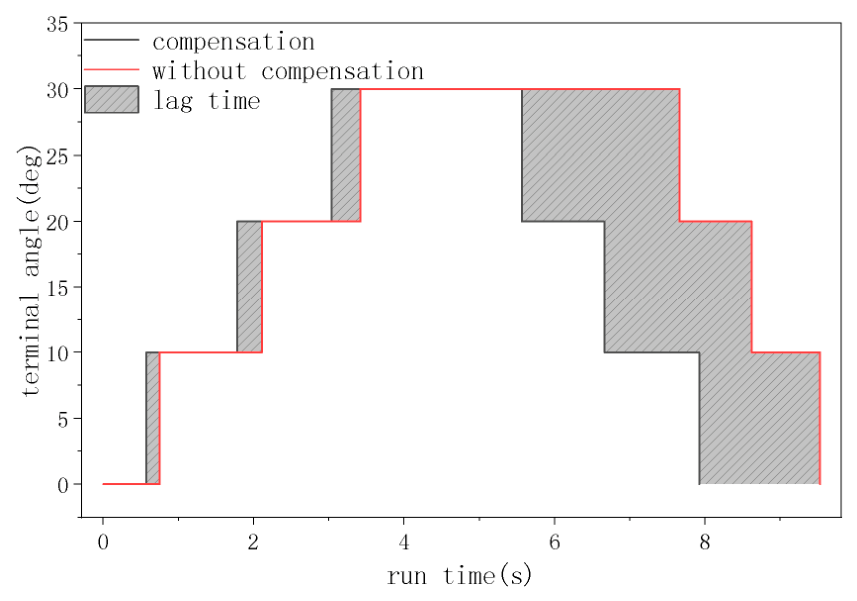
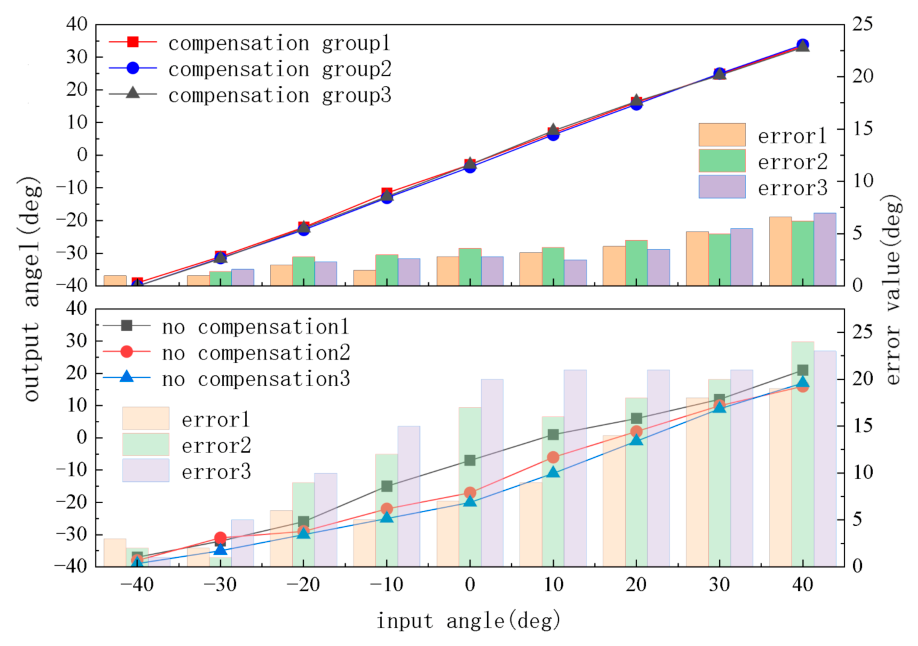
3.2. Experimental Results Analysis
4. Conclusions
- Geometric calibration via DH parameter identification effectively corrected deviations in the rigid transmission chain, bringing model predictions into closer agreement with measured poses and reducing positioning errors induced by assembly imperfections;
- The LuGre dynamic friction model successfully characterized the nonlinear and direction-dependent friction behavior at the cable–pulley interface, providing a physically grounded description of hysteresis and transmission asymmetry in cable-driven systems;
- The RBF neural network-based compensation framework accurately learned residual nonlinear errors not captured by the physics-based model, enabling precise representation and compensation of complex error characteristics arising from frictional hysteresis and structural coupling;
- Experimental validation demonstrated substantial performance gains: under identical control inputs, the compensated system achieved markedly improved positioning accuracy and dynamic response, with a pronounced reduction in hysteresis during motion reversal, confirming its effectiveness in mitigating path-dependent errors.
Author Contributions
Funding
Data Availability Statement
Conflicts of Interest
Abbreviations
| MIS | Minimally Invasive Surgery |
| DOF | Degree of Freedom |
| DH | Denavit–Hartenberg |
| RBF | Radial Basis Function |
| RMSE | Root Mean Square Error |
References
- Jeganathan, R.J.; Jegasothy, R.; Sia, T.W. Minimally invasive surgery: A historical and legal perspective on technological transformation. J. Robot. Surg. 2025, 19, 408. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Saridogan, E.; Antoun, L.; Bouwsma, A.V.E.; Clark, T.J.; Sardo, A.D.S.; Huirne, J.; Walker, T.S.; Tanos, V. European Society for Gynaecological Endoscopy (ESGE) Good Practice Recommendations on surgical techniques for removal of fibroids: Part 1 abdominal (laparoscopic and open) myomectomy. Facts Views Vis. ObGyn 2024, 16, 263–280. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Shinichi, Y.; Marie, H.; Noriko, I.; Masuda, T.; Tokunaga, M.; Kinugasa, Y. Robotic-assisted Surgery: Expanding Indication to Colon Cancer in Japan. J. Anus Rectum Colon 2022, 6, 77–82. [Google Scholar]
- Norihiko, I.; Go, W.; Yasumitsu, H.; Inaki, N.; Kawachi, K.; Oda, M. Robotic dexterity: Evaluation of three-dimensional monitoring system and non-dominant hand maneuverability in robotic surgery. J. Robot. Surg. 2007, 1, 231–233. [Google Scholar]
- Dragone, D.; Donadio, F.F.; Mirabelli, C.; Cosentino, C.; Amato, F.; Zaffino, P.; Spadea, M.F.; La Torre, D.; Merola, A. Design and Experimental Validation of a 3D-Printed Embedded-Sensing Continuum Robot for Neurosurgery. Micromachines 2023, 14, 1743. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Jason, B.; Giulio, P.; Dario, R.; Trevisani, A. Model predictive control for path tracking in cable driven parallel robots with flexible cables: Collocated vs. noncollocated control. Multibody Syst. Dyn. 2023, 58, 47–81. [Google Scholar] [CrossRef] [Scilit]
- Begey, J.; Cuvillon, L.; Lesellier, M.; Gouttefarde, M.; Gangloff, J. Dynamic Control of Parallel Robots Driven by Flexible Cables and Actuated by Position-Controlled Winches. IEEE Trans. Robot. 2019, 35, 286–293. [Google Scholar] [CrossRef] [Scilit]
- Jamshidifar, H.; Fidan, B.; Gungor, G.; Khajepour, A. Adaptive Vibration Control of a Flexible Cable Driven Parallel Robot. IFAC-Pap. 2015, 48, 1302–1307. [Google Scholar] [CrossRef] [Scilit]
- Xiao, B.; Alamdar, A.; Song, K.; Ebrahimi, A.; Gehlbach, P.; Taylor, R.H. Delta Robot Kinematic Calibration for Precise Robot-Assisted Retinal Surgery. In Proceedings of the 2022 International Symposium on Medical Robotics (ISMR); IEEE: New York, NY, USA, 2022. [Google Scholar]
- Zhang, W.; Zhang, F.; Zhang, J.; Zhang, S.; Zhang, J.; Zhang, J.; Sun, H.; Waters, K.E.; Ma, H. Research and analysis of an enhanced genetic algorithm identification method based on the LuGre model. PLoS ONE 2025, 20, e0322844. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Huang, H.; Li, Z.; Wang, S. Neural-network-based modeling and control of robotic manipulators. IEEE Trans. Ind. Electron. 2017, 64, 3892–3901. [Google Scholar]
- Brunton, S.L.; Noack, B.R.; Koumoutsakos, P. Machine learning for fluid mechanics. Annu. Rev. Fluid Mech. 2020, 52, 477–508. [Google Scholar] [CrossRef] [Scilit]
- Veitschegger, W.K.; Wu, C.-H. Robot calibration and compensation. IEEE J. Robot. Autom. 1988, 4, 643–656. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Park, C.; Kim, D.; Do, H.; Choi, T.; Choi, D.; Kim, B. The Effects of Design Parameters on the Mechanical Precision of an End Effector on a Parallel Kinematic Robot. J. Inst. Control. Robot. Syst. 2016, 22, 847–852. [Google Scholar] [CrossRef] [Scilit]
- Hanifzadegan, M.; Nagamune, R. Tracking and Structural Vibration Control of Flexible Ball–Screw Drives with Dynamic Variations. IEEE/ASME Trans. Mechatron. 2015, 20, 133–142. [Google Scholar] [CrossRef] [Scilit]
- Ryota, W.; Motoyasu, T. Principle of object support by Rope deformation and its application to Rope climbing by snake robot. Adv. Robot. 2023, 37, 591–602. [Google Scholar] [CrossRef] [Scilit]
- Lindenroth, L.; Housden, R.J.; Wang, S.; Back, J.; Rhode, K.; Liu, H. Design and Integration of a Parallel, Soft Robotic End-Effector for Extracorporeal Ultrasound. IEEE Trans. Biomed. Eng. 2020, 67, 2707. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Piao, J.; Kim, E.-S.; Choi, H.; Moon, C.-B.; Choi, E.; Park, J.-O.; Kim, C.-S. Indirect Force Control of a Cable-Driven Parallel Robot: Tension Estimation using Artificial Neural Network trained by Force Sensor Measurements. Sensors 2019, 19, 2520. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Tanev, T.K.; Cammarata, A.; Marano, D.; Sinatra, R. Elastostatic Model of a New Hybrid Minimally-Invasive-Surgery Robot. In Proceedings of the 14th IFToMM World Congress, Taipei, Taiwan, 25–30 October 2015; pp. 449–458. [Google Scholar]
- Dupont, P.E.; Simaan, N.; Choset, H.; Rucker, C. Continuum Robots for Medical Interventions. Proc. IEEE. Inst. Electr. Electron. Eng. 2022, 110, 847–870. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Zhang, F.; Shang, W.; Li, G.; Cong, S. Calibration of geometric parameters and error compensation of non-geometric parameters for cable-driven parallel robots. Mechatronics 2021, 77, 102595. [Google Scholar] [CrossRef] [Scilit]
- Wang, Z.; Liu, C.; Qian, S.; Wang, D.; Wei, X.; Yu, X. Tracking control with external force self-sensing ability based on position/force estimators and non-linear hysteresis compensation for a backdrivable cable-pulley-driven surgical robotic manipulator. Mech. Mach. Theory 2023, 183, 105259. [Google Scholar] [CrossRef] [Scilit]






| Serial Number | Type | Variable | Action | Scope |
|---|---|---|---|---|
| 1 | revolute pair | rotate around Z | ||
| 2 | translational pair | Move along Z | ||
| 3 | revolute pair | rotate around Y | ||
| 4 | revolute pair | rotate around X |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Yu, S.; Song, Y.; Ye, C.; Li, H.; Shi, C. Error Analysis and Drive Optimization of a Minimally Invasive Surgical Robot. Machines 2026, 14, 584. https://doi.org/10.3390/machines14060584
Yu S, Song Y, Ye C, Li H, Shi C. Error Analysis and Drive Optimization of a Minimally Invasive Surgical Robot. Machines. 2026; 14(6):584. https://doi.org/10.3390/machines14060584
Chicago/Turabian StyleYu, Suyang, Yihao Song, Changlong Ye, Huaiyong Li, and Chaoben Shi. 2026. "Error Analysis and Drive Optimization of a Minimally Invasive Surgical Robot" Machines 14, no. 6: 584. https://doi.org/10.3390/machines14060584
APA StyleYu, S., Song, Y., Ye, C., Li, H., & Shi, C. (2026). Error Analysis and Drive Optimization of a Minimally Invasive Surgical Robot. Machines, 14(6), 584. https://doi.org/10.3390/machines14060584