1. Introduction
Debris flows are among the most hazardous and complex mass-movement processes affecting steep mountainous areas, posing significant threats to human life, property, and infrastructure [
1,
2]. Their behaviour results from strongly nonlinear interactions among topographic forcing, granular–fluid rheology, sediment availability, and hydrological triggering, which makes reliable prediction intrinsically difficult [
3,
4,
5]. For this reason, a broad hierarchy of numerical models has been developed to simulate debris-flow propagation, ranging from simplified one-dimensional (1D) depth-averaged formulations to fully two-dimensional continuum approaches [
6].
Mathematical and numerical modelling is central to debris-flow research for process analysis, forecasting, and impact assessment. These models are generally based on mass and momentum conservation, with constitutive or empirical closure relations. Computational Fluid Dynamics (CFDs) [
7,
8] provides detailed simulations, but its fully 3D formulations are computationally demanding; hence, shallow-water models are widely adopted [
9,
10,
11].
The governing equations are solved by discretizing the computational domain, allowing the evolution of stress, velocity, and flow thickness to be computed. Common approaches include the Finite Element Method (FEM) [
12], the Finite Volume Method (FVM) [
13], Smoothed Particle Hydrodynamics (SPHs) [
14,
15], and the Particle Finite Element Method (PFEM) [
16,
17]. Despite major advances, these solvers remain computationally demanding and may face stability issues over steep and irregular terrain, as well as in wet–dry transitions and rapidly evolving flows [
18,
19].
Comparative studies show that different simulation codes can reproduce observed runout and deposition [
20,
21,
22,
23,
24,
25,
26], though results remain sensitive to rheological assumptions and topographic resolution [
27,
28,
29]. Many advanced solvers, including FLO-2D PRO, RAMMS, and DAN3D, are also proprietary and require paid licences [
30,
31,
32], which may limit methodological transparency, hinder reproducibility, and, more broadly, constrain scientific progress. This, together with the limited availability of observational debris-flow datasets, restricts the use of purely data-driven machine-learning approaches, which generally require large labelled datasets.
Recent studies identify surrogate modelling, especially operator-learning techniques, as a promising way to address these limitations [
33,
34,
35,
36]. By approximating the input–output mapping of numerical solvers, surrogate models reduce computational cost while retaining physical consistency when trained on synthetic or observational data [
37]. Within this framework, Fourier Neural Operators (FNOs) have emerged as effective tools for learning solution operators and approximating parametric partial differential equations efficiently [
38,
39,
40]. They have already shown strong performance in advection–diffusion and geophysical transport problems, enabling stable, mesh-independent, and near-instantaneous predictions of full space–time fields.
Previous work showed that FNOs can model debris flows in simplified 1D settings, reproducing a validated 1D shallow-flow solver with solid accuracy at much lower computational cost [
41]. However, this framework cannot represent lateral spreading, cross-slope velocities, or explicit 2D geomorphological controls on deposition, motivating a fully 2D formulation.
In this study, we extend the FNO to 2D debris-flow modelling in a hazard-oriented framework. We develop and assess a physics-based surrogate, trained on synthetic simulations, to reproduce debris-flow dynamics over real terrain in space and time. Training data are generated with a validated 2D shallow-flow solver, allowing the model to learn the spatio-temporal evolution of flow thickness and depth-averaged velocity under varying topographic and physical conditions. In the absence of large real spatio-temporal datasets, the use of a numerical solver validated against real calibrated events provides a physically grounded way to generate synthetic simulations suitable for training the surrogate model.
The study is also motivated by the need to support susceptibility assessment in areas exposed to hydrogeological hazards, especially where debris flows may threaten residential sectors and local infrastructure. The March 2021 Morino–Rendinara event [
6] represents a significant example of a hydrogeological hazard, having mobilized several hundred cubic metres of material, partially obstructing the Liri riverbed, and exposing nearby infrastructure to the rapid propagation of debris flows. Accordingly, this area will serve as a reference site for the development of site-specific hazard-oriented simulations within the basin.
The work addresses two main challenges: the scarcity of high-quality observational data and the computational cost of traditional solvers. To this end, simulations are performed on local 2D domains embedded in the 3D topography of the Rendinara–Morino area, while preserving its main geomorphological features and detachment configurations.
For this reason, the present study relies on an in-house numerical solver designed both to reproduce debris-flow propagation over complex terrain and to generate physically consistent outputs directly usable for dataset construction, storage, and AI training. Achieving the same level of control and integration with external codes would have been far more cumbersome. These data are then used to train a dynamic 3D Fourier Neural Operator (FNO) model in , conditioned on terrain, friction, bulk density, and initial detachment conditions, with training performed using GPU acceleration.
Compared with earlier 1D studies, the present 2D formulation captures lateral spreading, channelization, and planimetric deposition, while introducing greater sensitivity to topographic complexity and wet–dry fronts. We also examine the training objective by adopting a masked and weighted loss that emphasizes active-flow regions and velocity reconstruction, both especially relevant for hazard-oriented applications.
The main objective is to propose a fast and general surrogate-modelling framework for solver-consistent landslide runout simulations, and to demonstrate its application through the Morino–Rendinara case study. In this context, the trained surrogate developed here is specifically tailored to the Morino–Rendinara geomorphological setting and to the parameter space explored in this study; as such, it should be interpreted as a Morino-specific model rather than a universally transferable trained model. Nevertheless, the overall framework is general and can be applied to other study areas, provided that appropriate site-specific training datasets are generated to capture the relevant geomorphological features and parameter ranges. This approach may support location-specific surrogate models for debris-flow hazard assessment, providing efficient predictions consistent with numerical solvers and tailored to individual catchments. The expected computational advantage is relevant not only for large scenario ensembles and uncertainty analyses, but also for single simulations, suggesting possible integration with monitoring networks in operational early-warning frameworks for hydrogeological risk.
2. Study Area
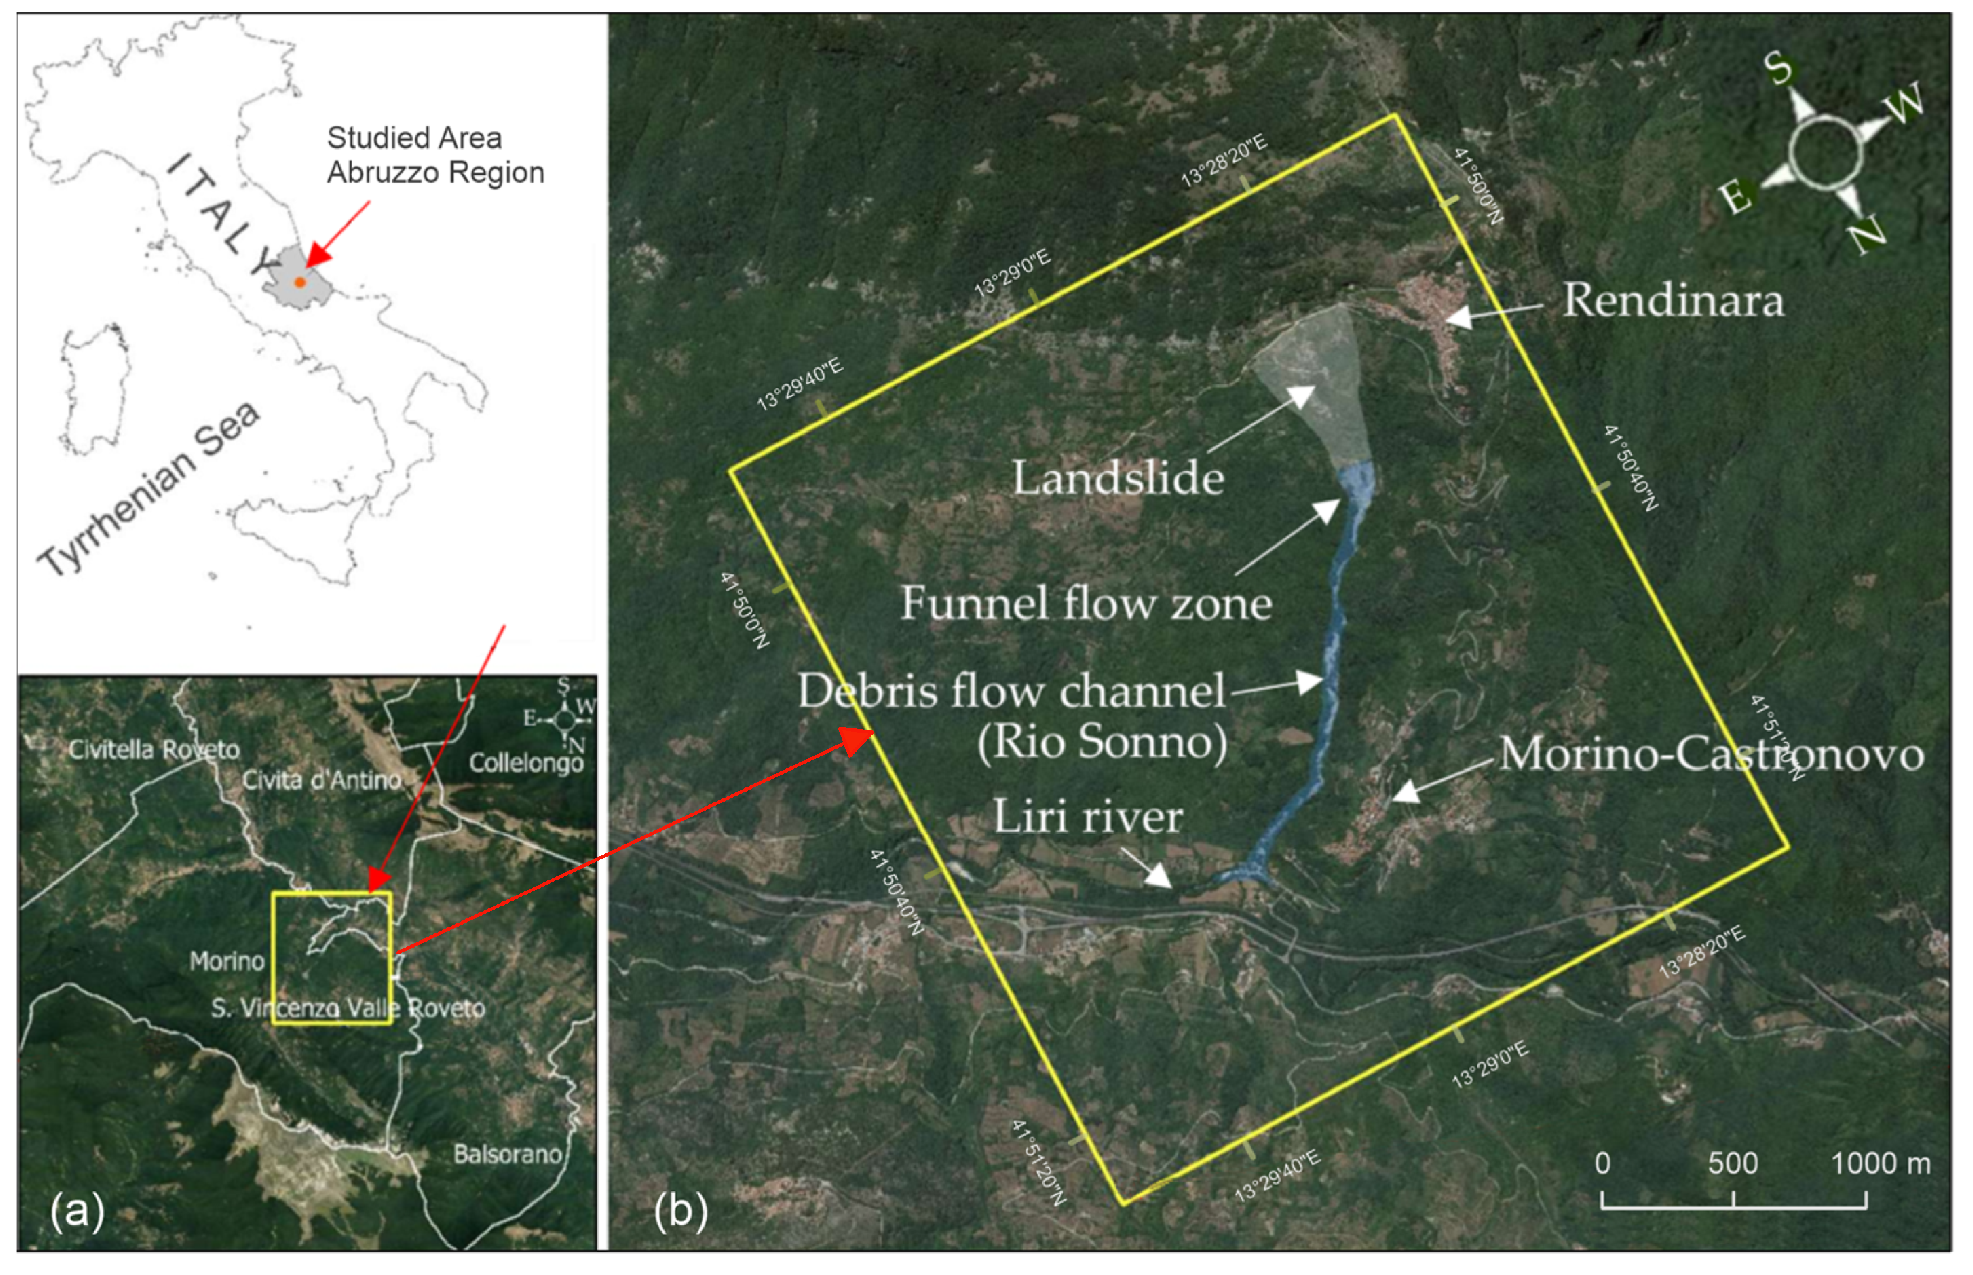
This section presents the characterization of the Morino–Rendinara area (
Figure 1), which we aim to represent using the FNO model. The objective is to describe the geomorphological and physical attributes of this debris-flow system in a form suitable for integration within an FNO framework.
The synthetic dataset developed in this work was inspired by the debris-flow event that occurred in March 2021 in the Morino–Rendinara area (Abruzzo Region, central Italy), along the Rio Sonno channel, a tributary of the Liri River [
6]. The study area is located near the hamlet of Rendinara, within the Municipality of Morino, in the upper part of the Roveto Valley on the eastern side of the Liri River valley [
6]. During the March 2021 event, several hundred cubic metres of material were mobilized, partially obstructing the Liri riverbed and temporarily altering the local hydrogeological regime [
6].
3. Materials and Methods
3.1. Physical Model: 2D Governing Equations for Debris-Flow Modelling
Debris-flow propagation is described here within a depth-averaged 2D framework, in which the moving mass is represented as a shallow continuum flowing over a prescribed topography. Under the shallow-flow assumption, the characteristic flow thickness is small compared with the typical horizontal length scale, so that the full 3D problem can be reduced to a system of depth-integrated balance equations. This approximation is well suited for rapid gravity-driven flows over natural terrain, where the dominant controls are topographic forcing, hydrostatic pressure gradients, and basal resistance. In the present formulation, the bulk density is treated as a material property and is assumed to be spatially uniform and temporally constant. In our physical model, this assumption is a simplification of the real process, since actual debris flows may exhibit spatial and temporal variations.
Let
denote the bed elevation,
the flow thickness, and
the depth-averaged velocity components in the horizontal directions
x and
y. The free-surface elevation is defined as
From a physical point of view, the debris flow is governed by depth-integrated conservation of mass and momentum. The continuity equation reads
where
represents a possible external inflow contribution and
E denotes the erosion–entrainment rate. Phase segregation is not explicitly modelled; deposition is assumed when the local depth-averaged velocity tends to zero.
The corresponding momentum equations in the two horizontal directions are
where
g is the gravitational acceleration, and
and
are the basal shear-stress components acting along the two horizontal directions.
Equations (
2)–(
4) show the main physical mechanisms controlling debris-flow propagation: conservation of mass, advection of momentum, hydrostatic pressure forces, gravitational forcing induced by bed gradients, and basal resistance. In particular, the terms
and
represent the driving effect of the terrain, whereas the basal shear stresses oppose the motion and describe the rheological resistance of the flowing mass.
For compactness, the same system can be written in conservative vector form by introducing the vector of conserved variables
so that
where
and
are the depth-integrated flux vectors and
collects the source terms associated with bed slope, basal resistance, inflow, and erosion–entrainment.
The flux vectors are
and the source-term vector may be written formally as
For the Morino–Rendinara zone, consistently with [
6], basal resistance is represented through a Voellmy-type [
42] combining a Coulomb-like frictional contribution with a velocity-dependent turbulent term. The basal shear-stress magnitude is written as
where
is the dry-friction coefficient,
is the turbulent friction parameter,
is the flow speed, and
is the effective normal acceleration. In the absence of curvature corrections, the latter reduces to
where
is the local slope angle. More generally, if curvature effects are taken into account, the effective normal acceleration may be written as
where
is a curvature-related contribution depending on the local velocity field and terrain curvature.
To obtain the Cartesian components entering the momentum equations, the basal shear stress is projected along the flow direction as
where
is a small regularization parameter introduced to avoid division by zero in nearly stagnant cells.
Depending on the modelling assumptions, the mass balance may also include localized external supply terms and entrainment from the bed. In the latter case, erosion–entrainment is commonly activated when the basal shear stress exceeds a critical threshold
[
43]. A simple threshold-based entrainment law may therefore be written as
where
is an empirical entrainment coefficient. Equivalently, the same relation may be expressed in compact form as
This expression indicates that erosion begins only when the basal stress exceeds the critical threshold, and subsequently increases with the excess shear stress, which can also be addressed within a probabilistic framework [
44].
The physical problem is completed by appropriate initial and boundary conditions. The initial condition specifies the starting distribution of flow thickness and momentum within the computational domain and may represent either an instantaneous release or a time-dependent supply of material.
3.2. Numerical Solver: Finite-Volume Scheme
The full numerical formulation of our in-house solver is reported in
Appendix A.1. In the present implementation, the solver adopts a depth-averaged shallow-flow formulation with spatially uniform and temporally constant bulk density, Voellmy-type basal friction with spatially distinct selectable basal-friction regions consistently with [
6], threshold-based erosion–entrainment, no explicit phase segregation, and deposition assumed to occur as the local depth-averaged velocity approaches zero. The depth-averaged equations introduced above are solved with a finite-volume scheme on a structured Cartesian grid derived from the DEM. Conserved variables are stored as cell averages and updated from intercell numerical fluxes and source terms. The scheme is designed to remain stable over irregular topography, preserve non-negative flow thickness, and handle wet–dry transitions consistently.
To balance accuracy and robustness, the solver adopts a higher-order treatment in regular flow conditions and a more diffusive formulation near locally critical states. Time integration is explicit and satisfies a Courant–Friedrichs–Lewy (CFL) stability condition. This makes the method efficient and robust for generating a large ensemble of synthetic simulations used to train the surrogate model.
The full numerical formulation reported in
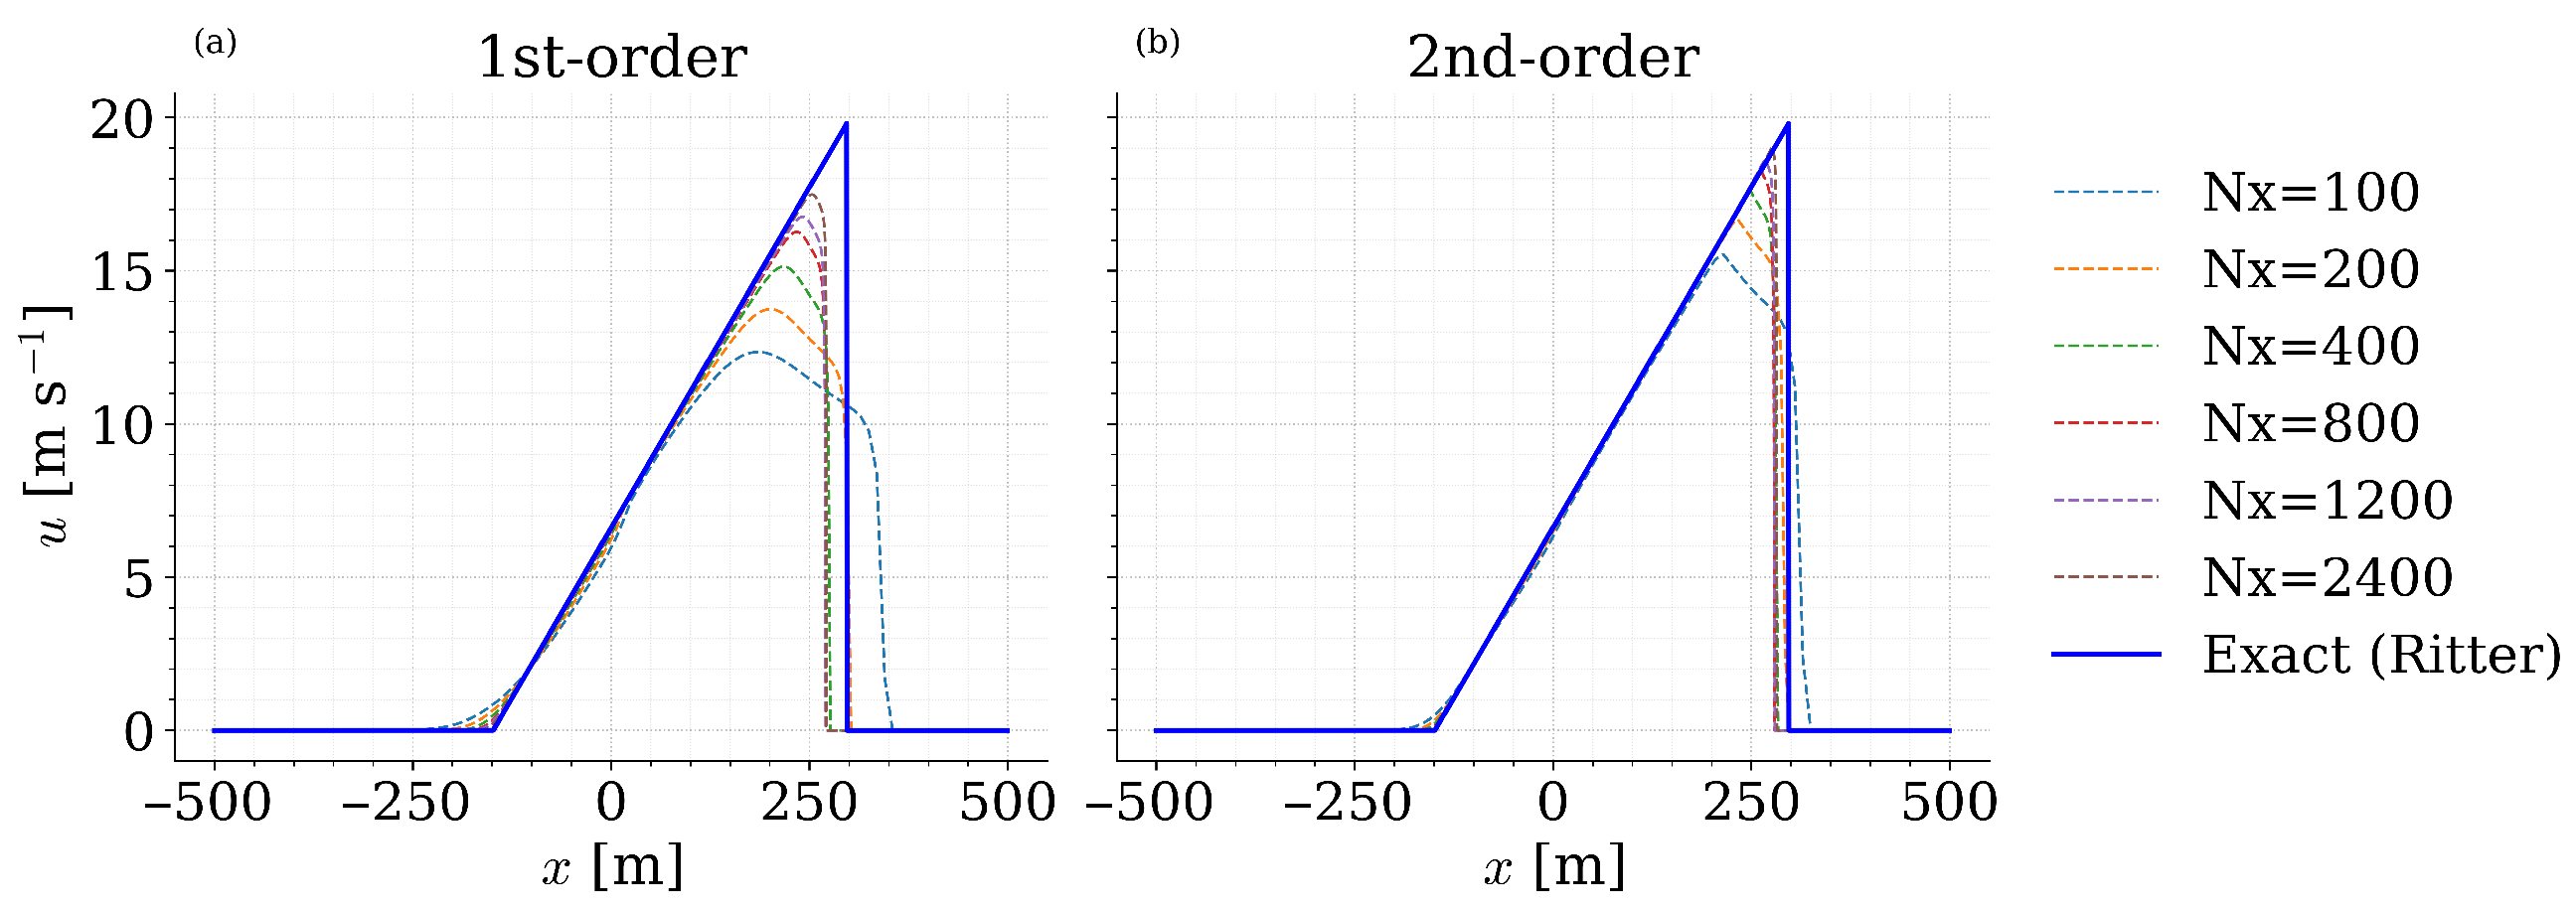
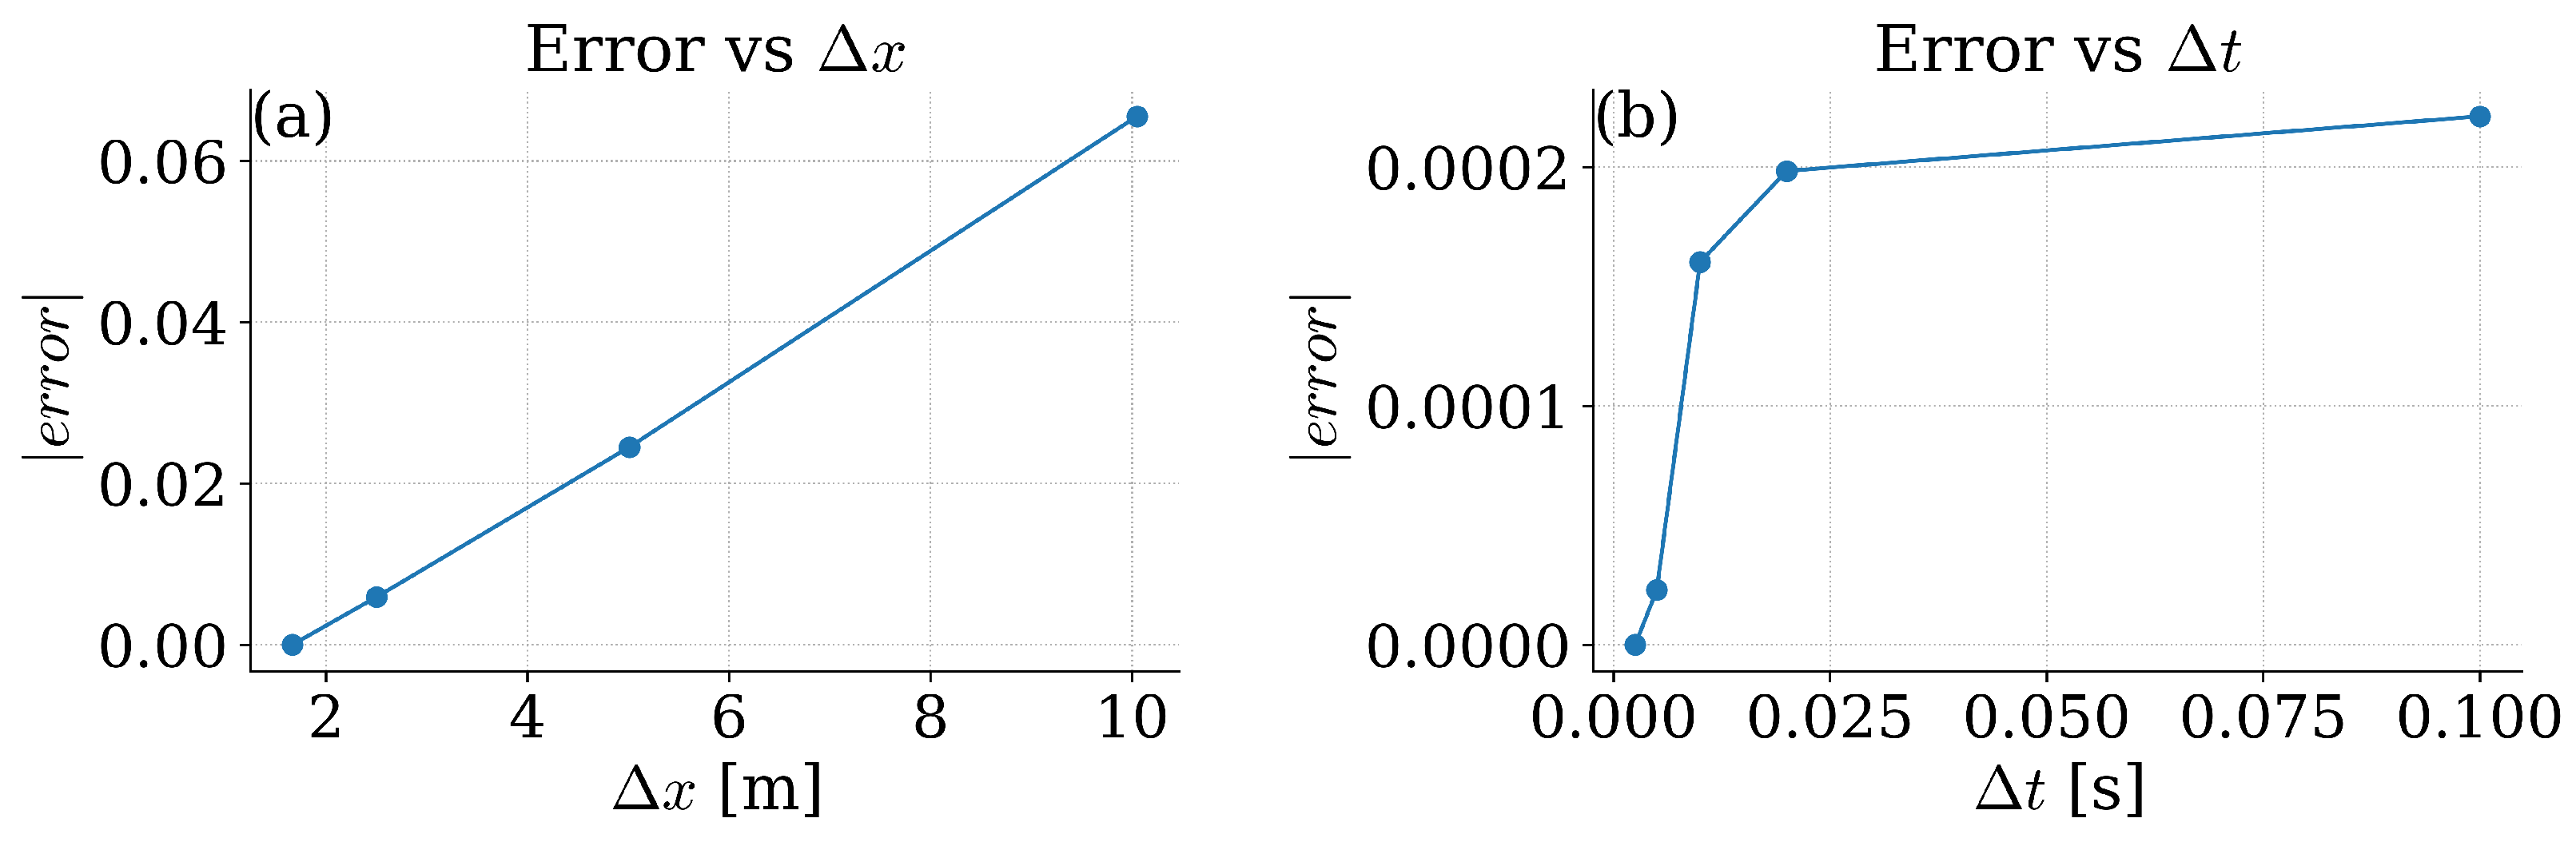
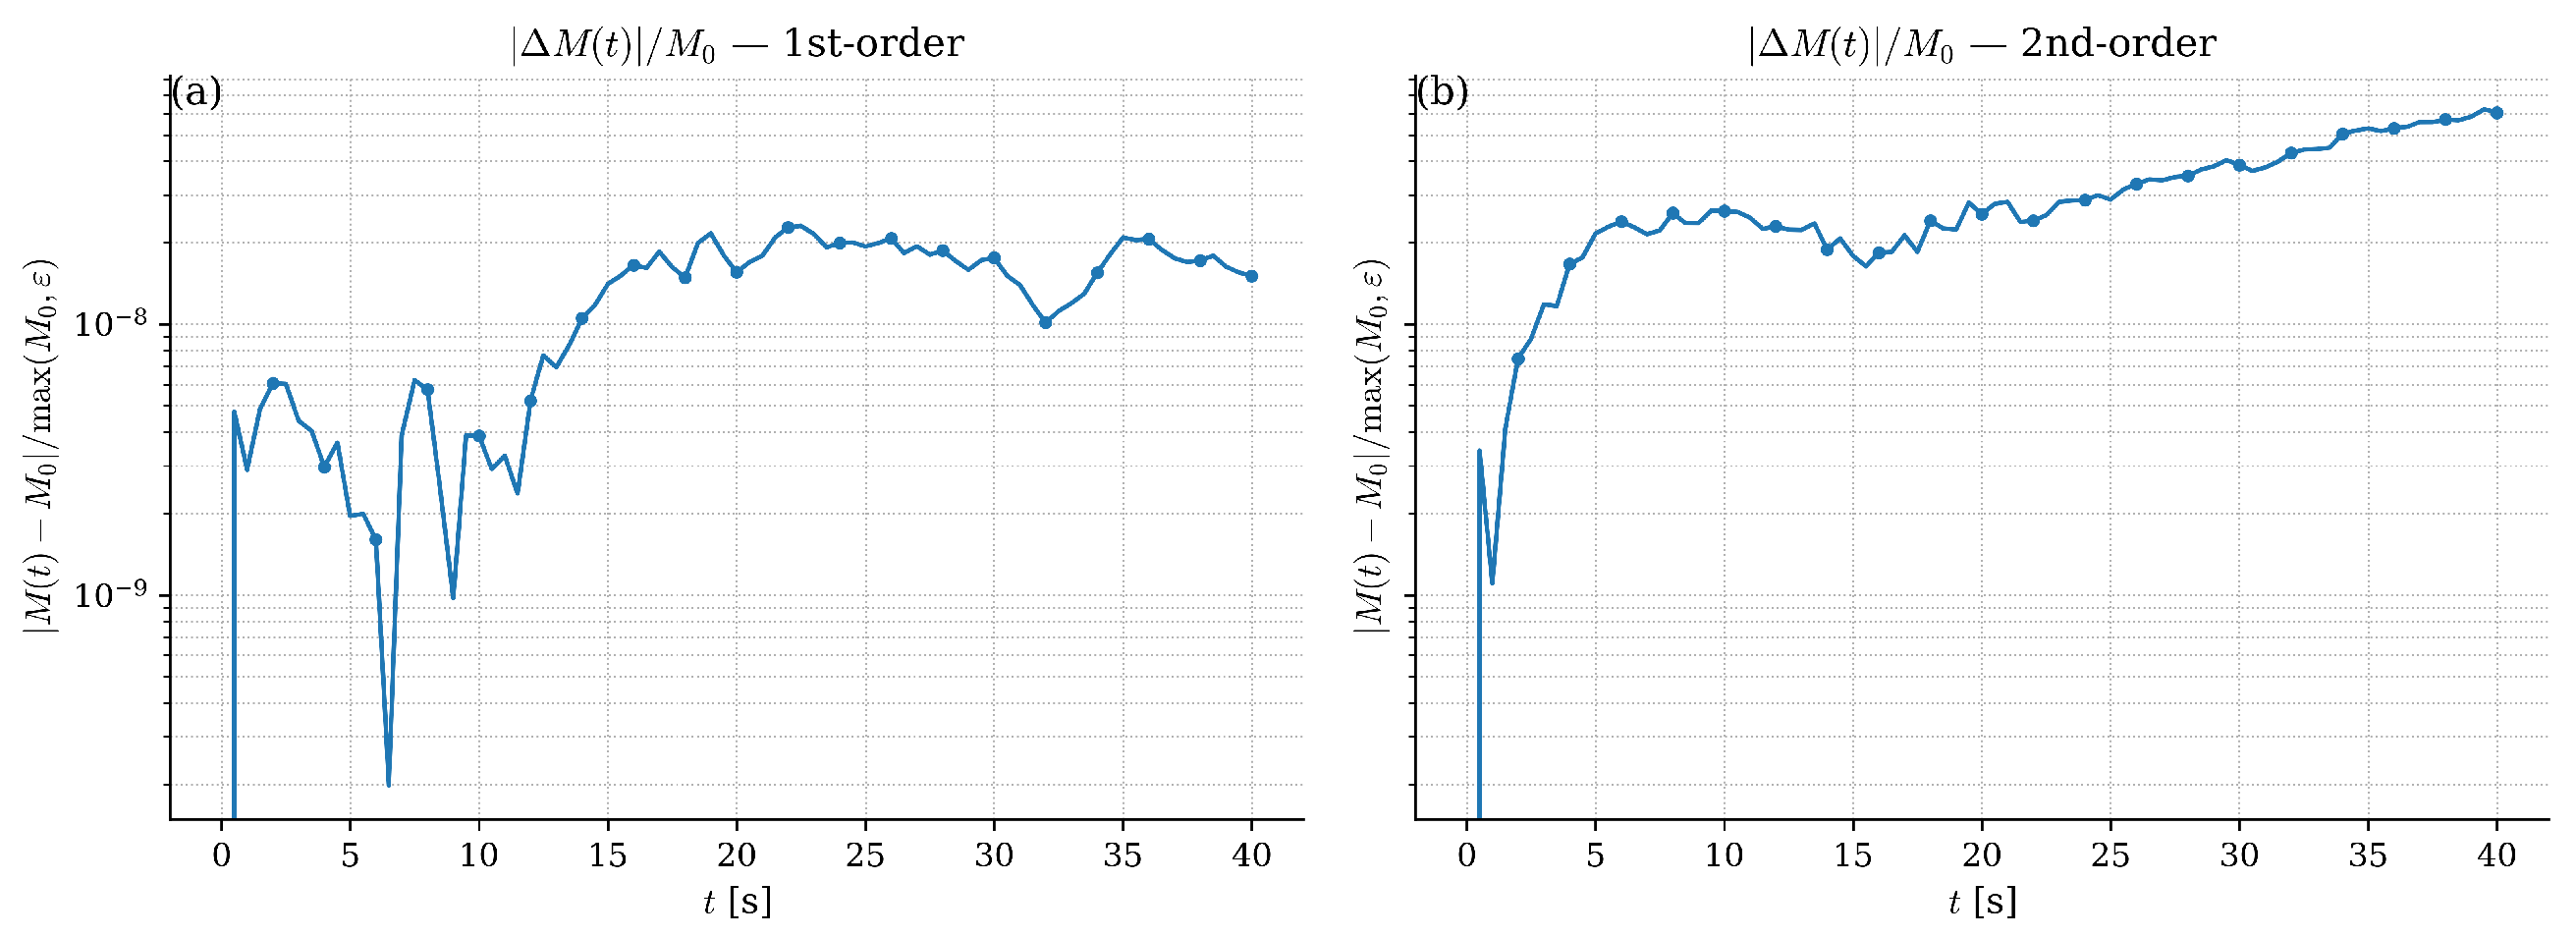
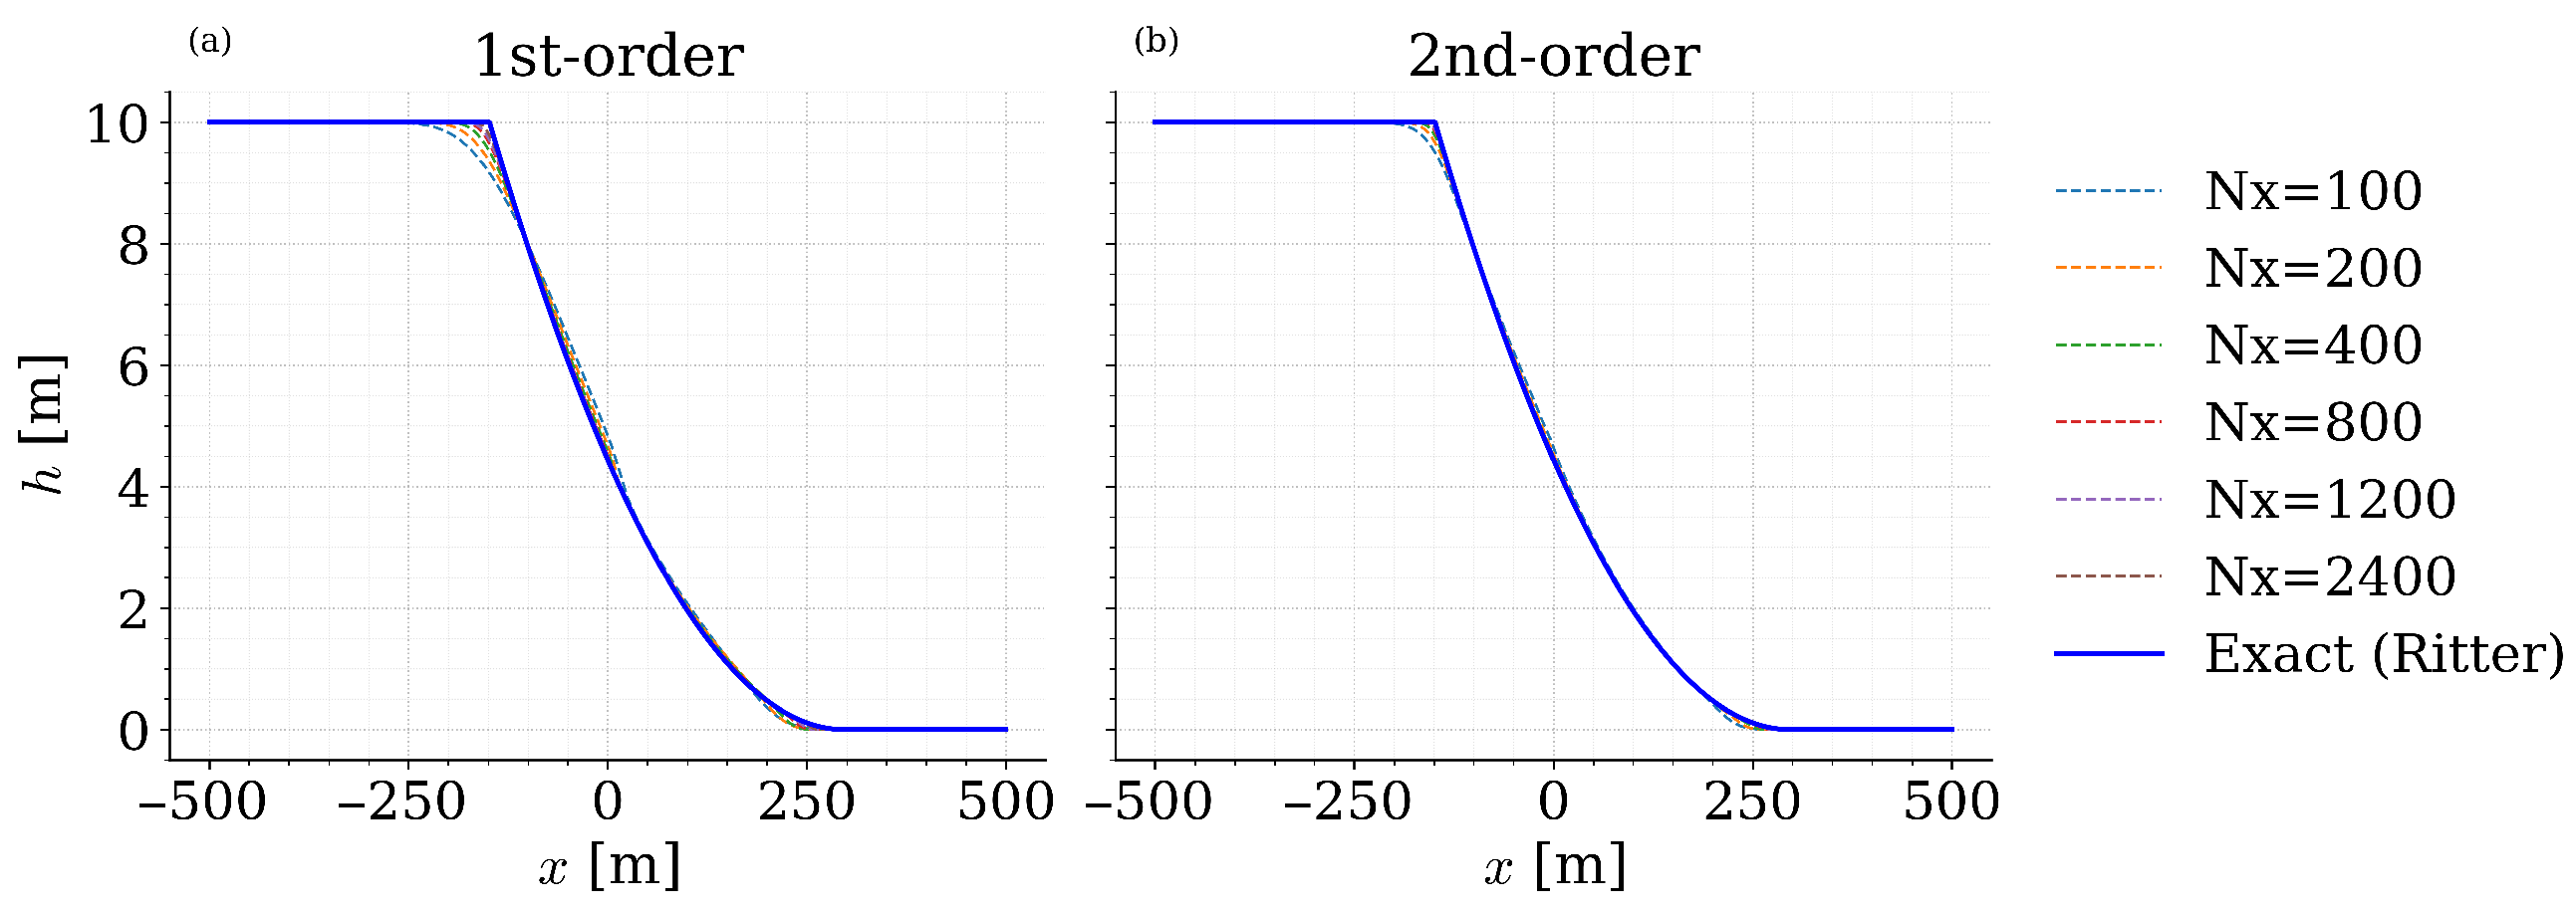
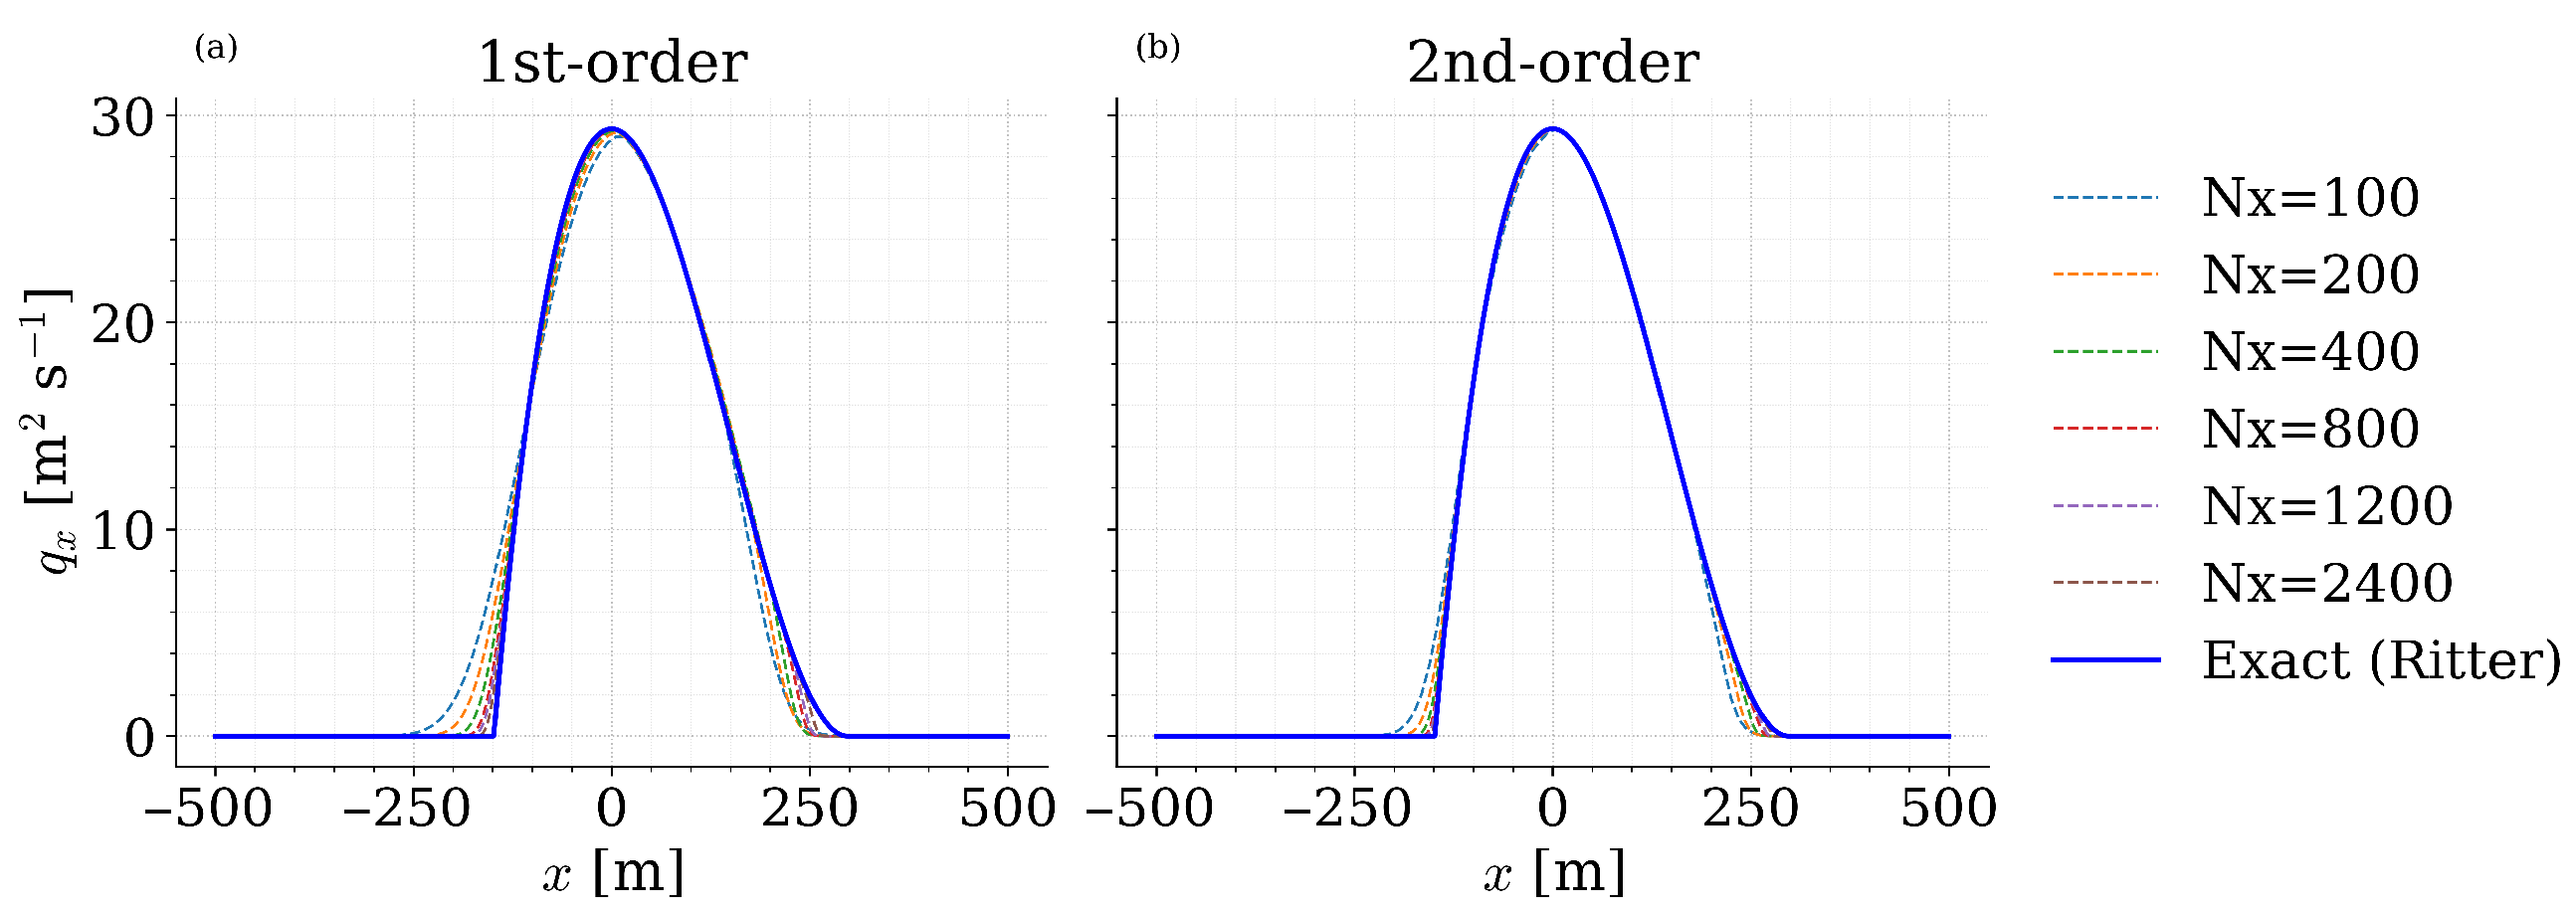
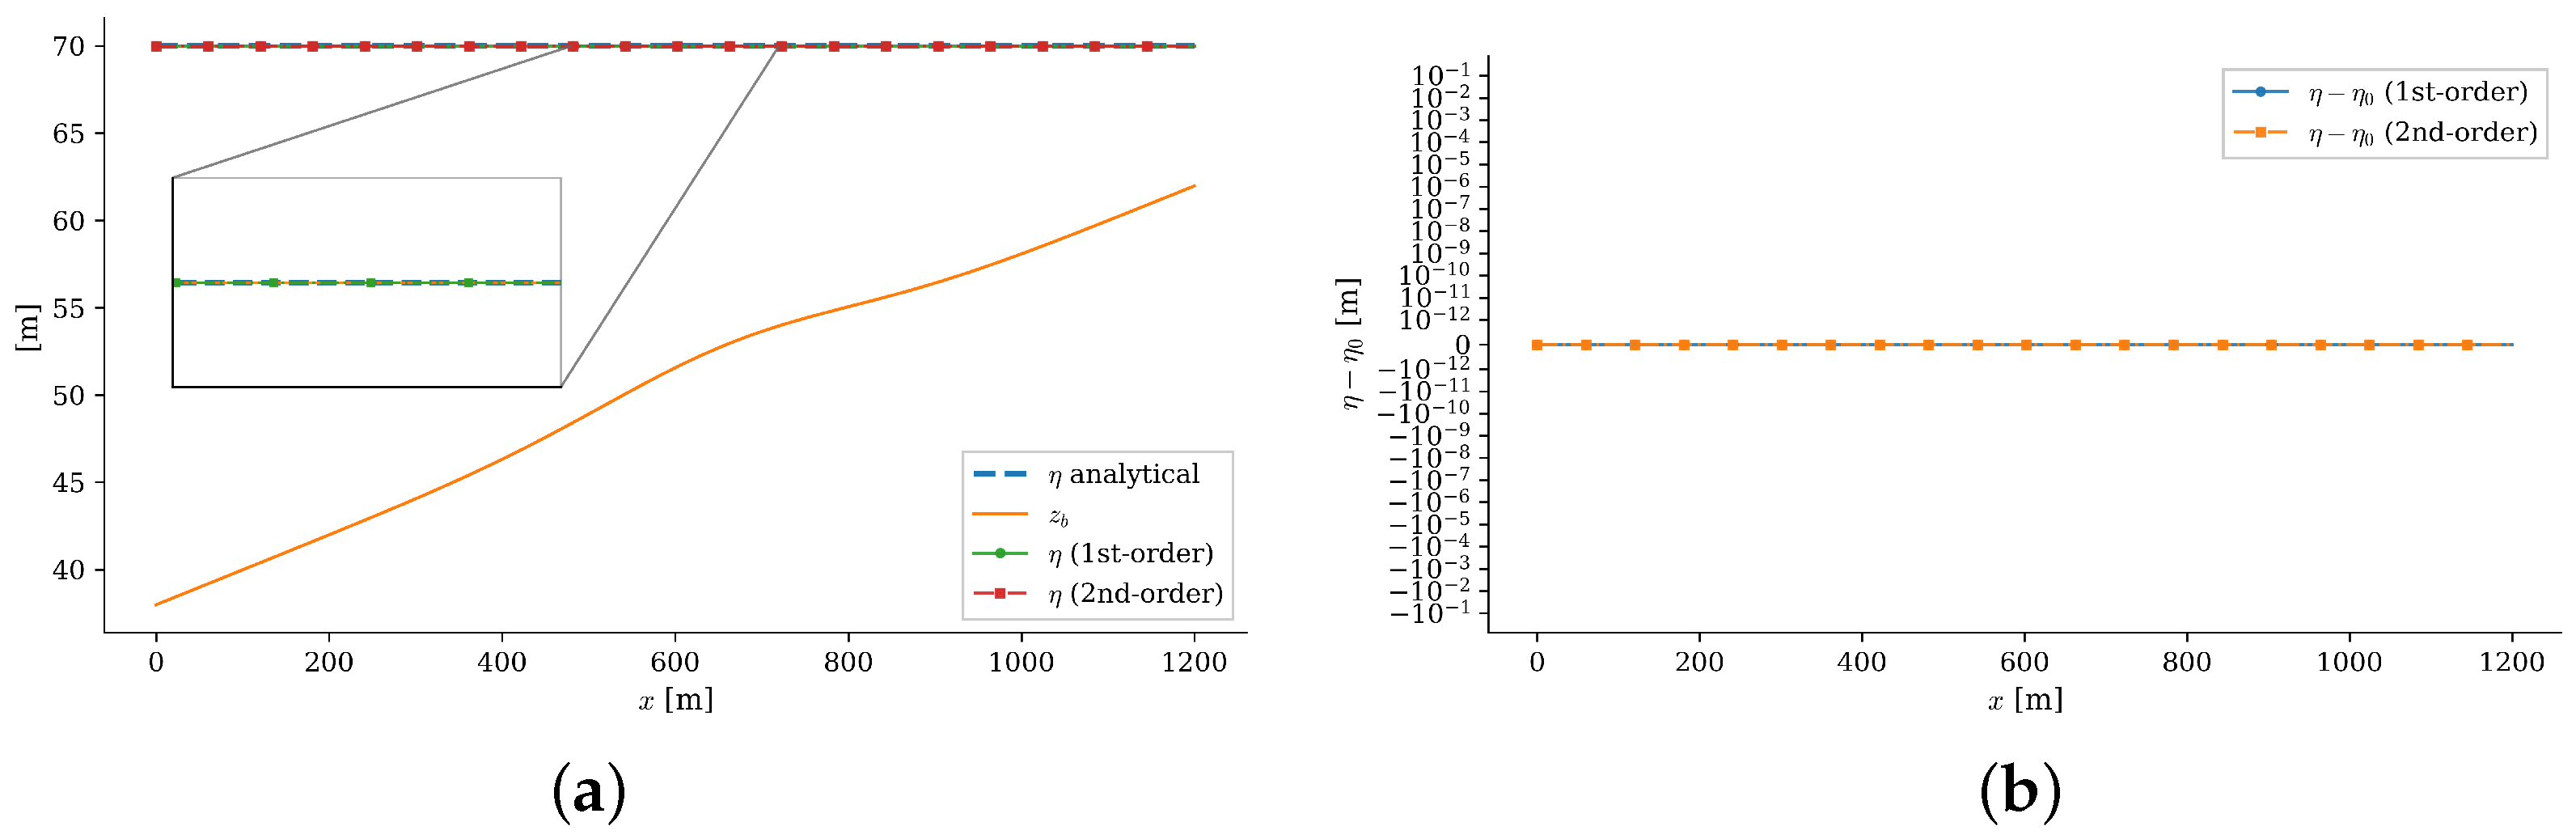
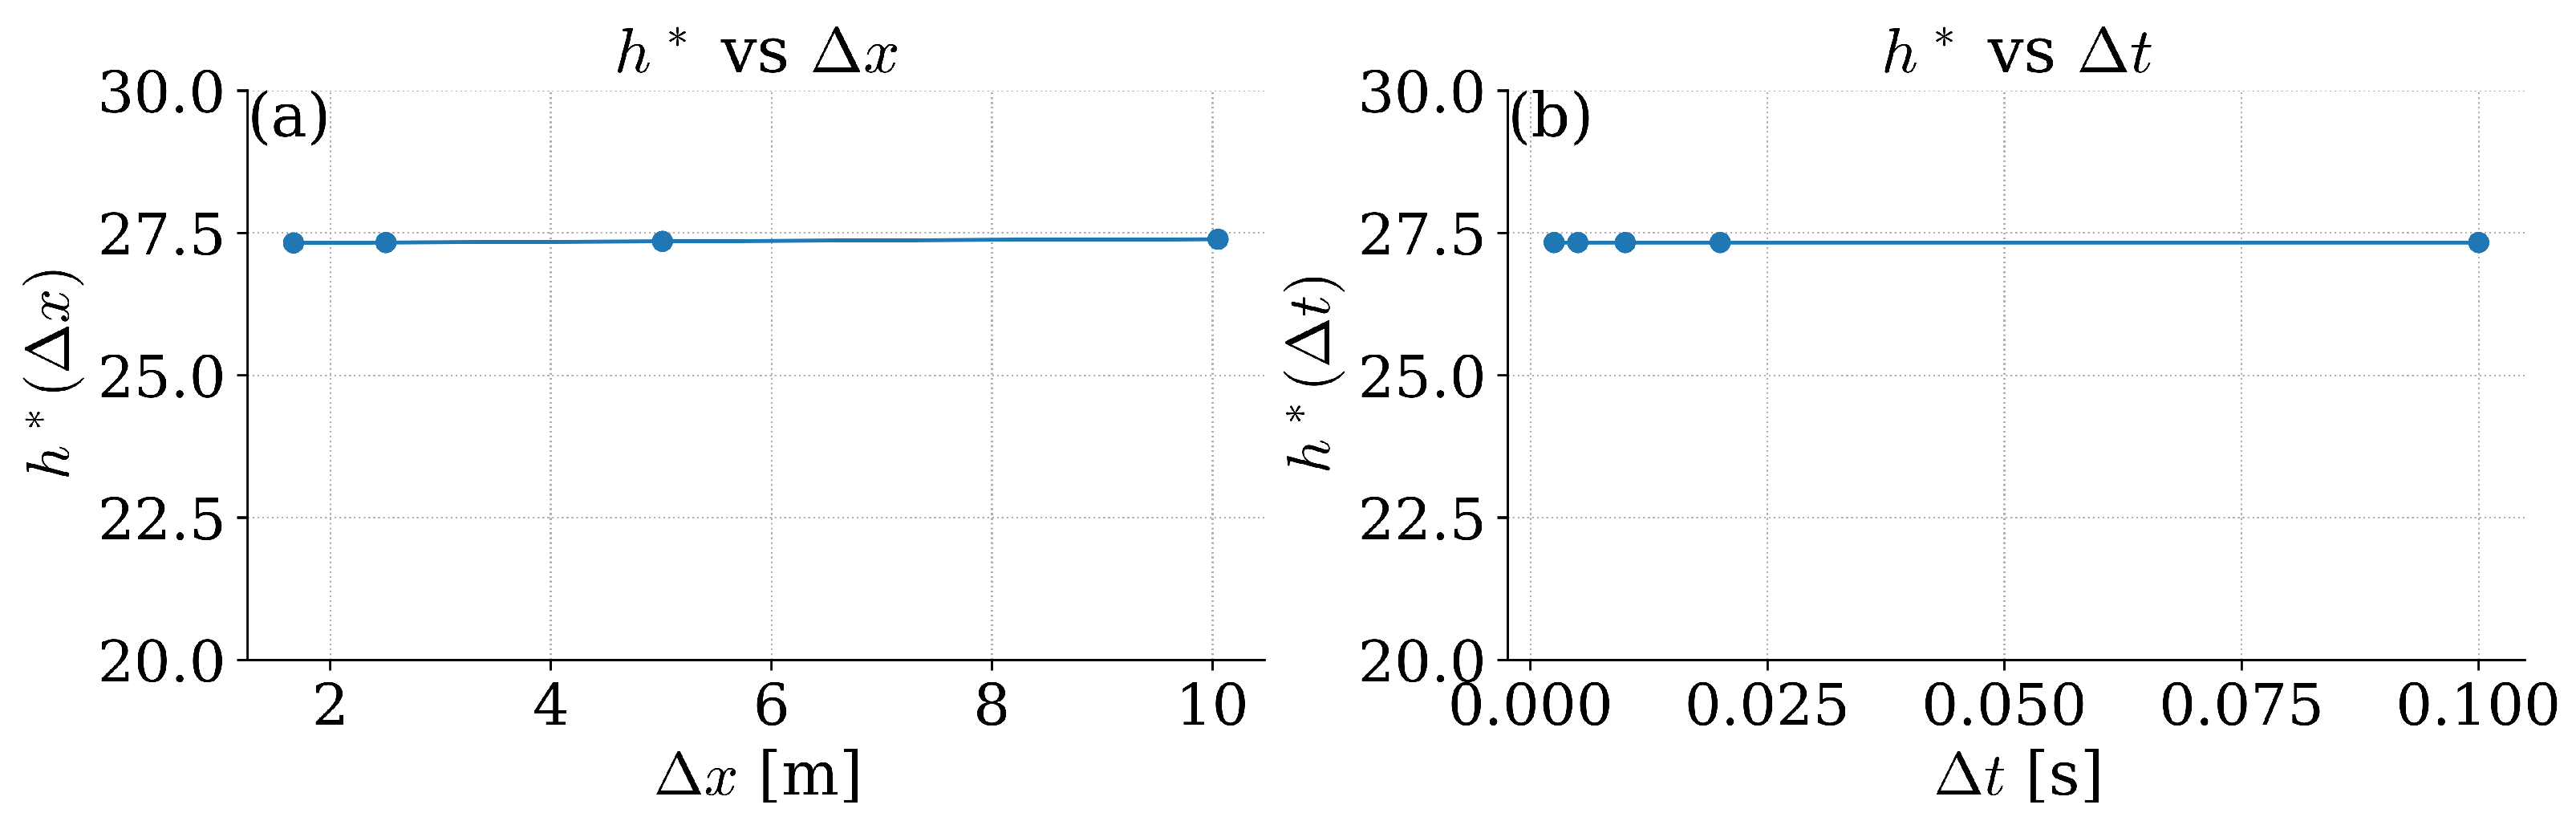
Appendix A.1 includes the finite-volume update, approximate Riemann solver, hydrostatic reconstruction, Monotonic Upstream-centred Schemes for Conservation Laws (MUSCL), hybrid first–second–order strategy, time integration, and wet–dry treatment. Solver validation is presented in
Appendix A.2, including analytical benchmarks in
Appendix A.2.1 and
Appendix A.2.2, convergence tests in
Appendix A.2.3, conservation tests in
Appendix A.2.4, and comparisons with real debris-flow case studies in
Appendix A.3.
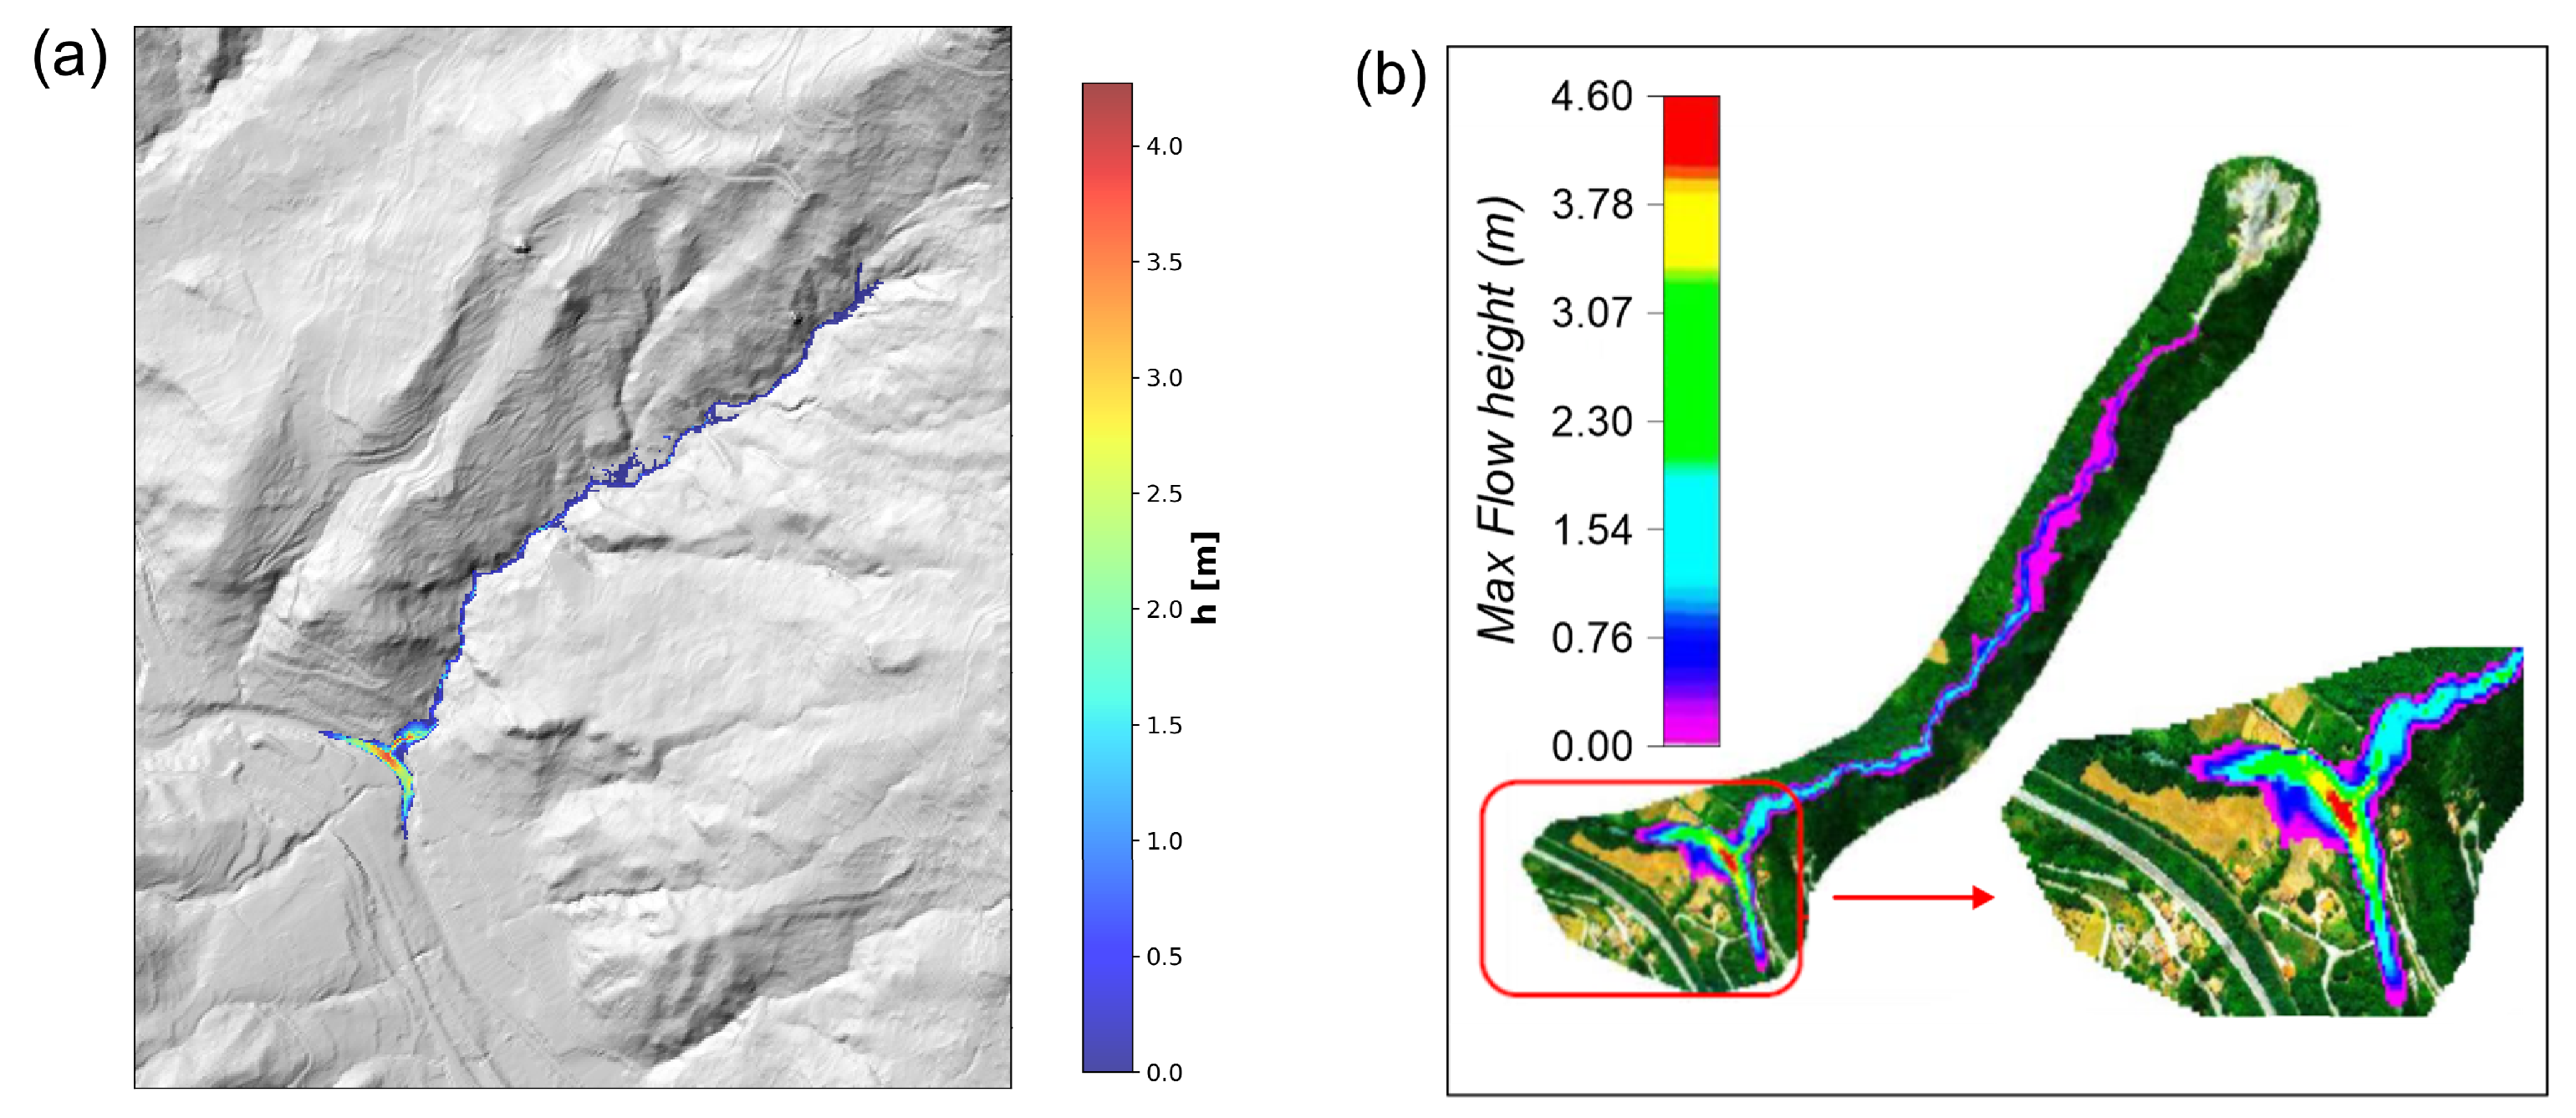
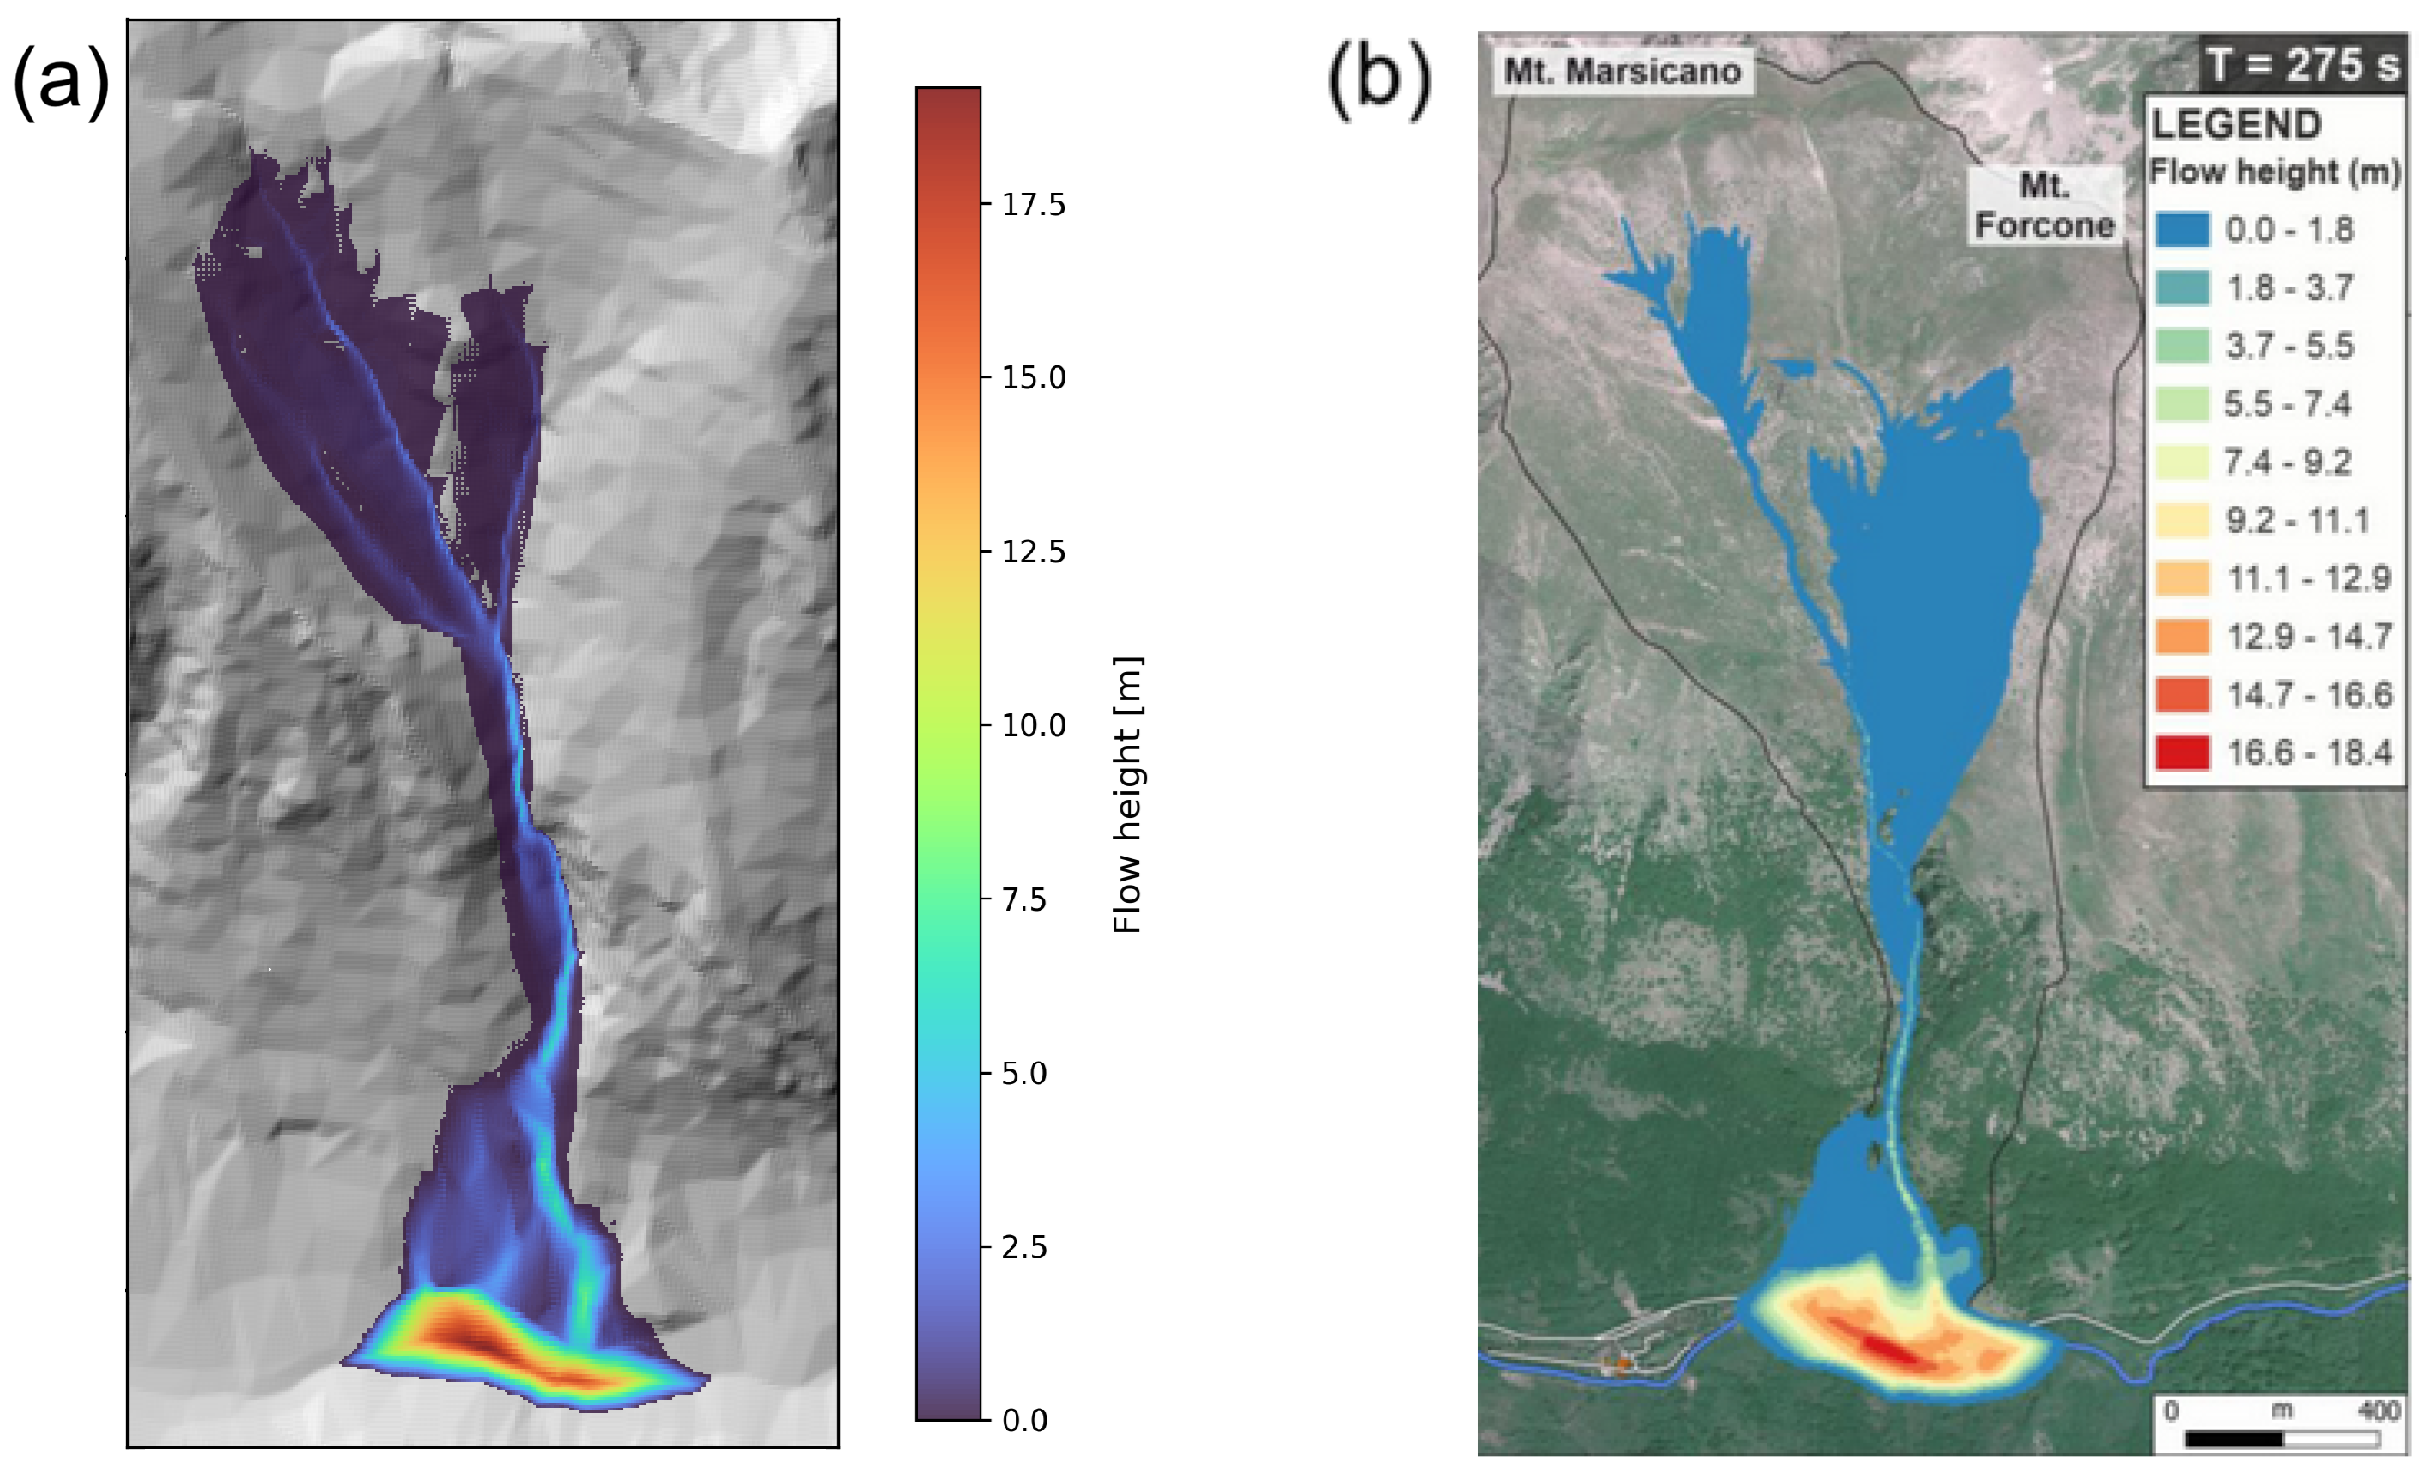
An important real-case validation is provided by the Morino–Rendinara debris flow, which was reproduced and compared with the back-analysis of Pasculli et al. [
6]. In their study, the event was simulated using RAMMS v1.5, adopting a shallow-water model coupled with a Voellmy-type rheology. They reported a flow thickness of about
. Using the same input parameters, our simulation showed significant agreement with the observed evidence. Further details are given in
Appendix A.3.1.
3.3. Dataset Parameter Space and Numerical Setup
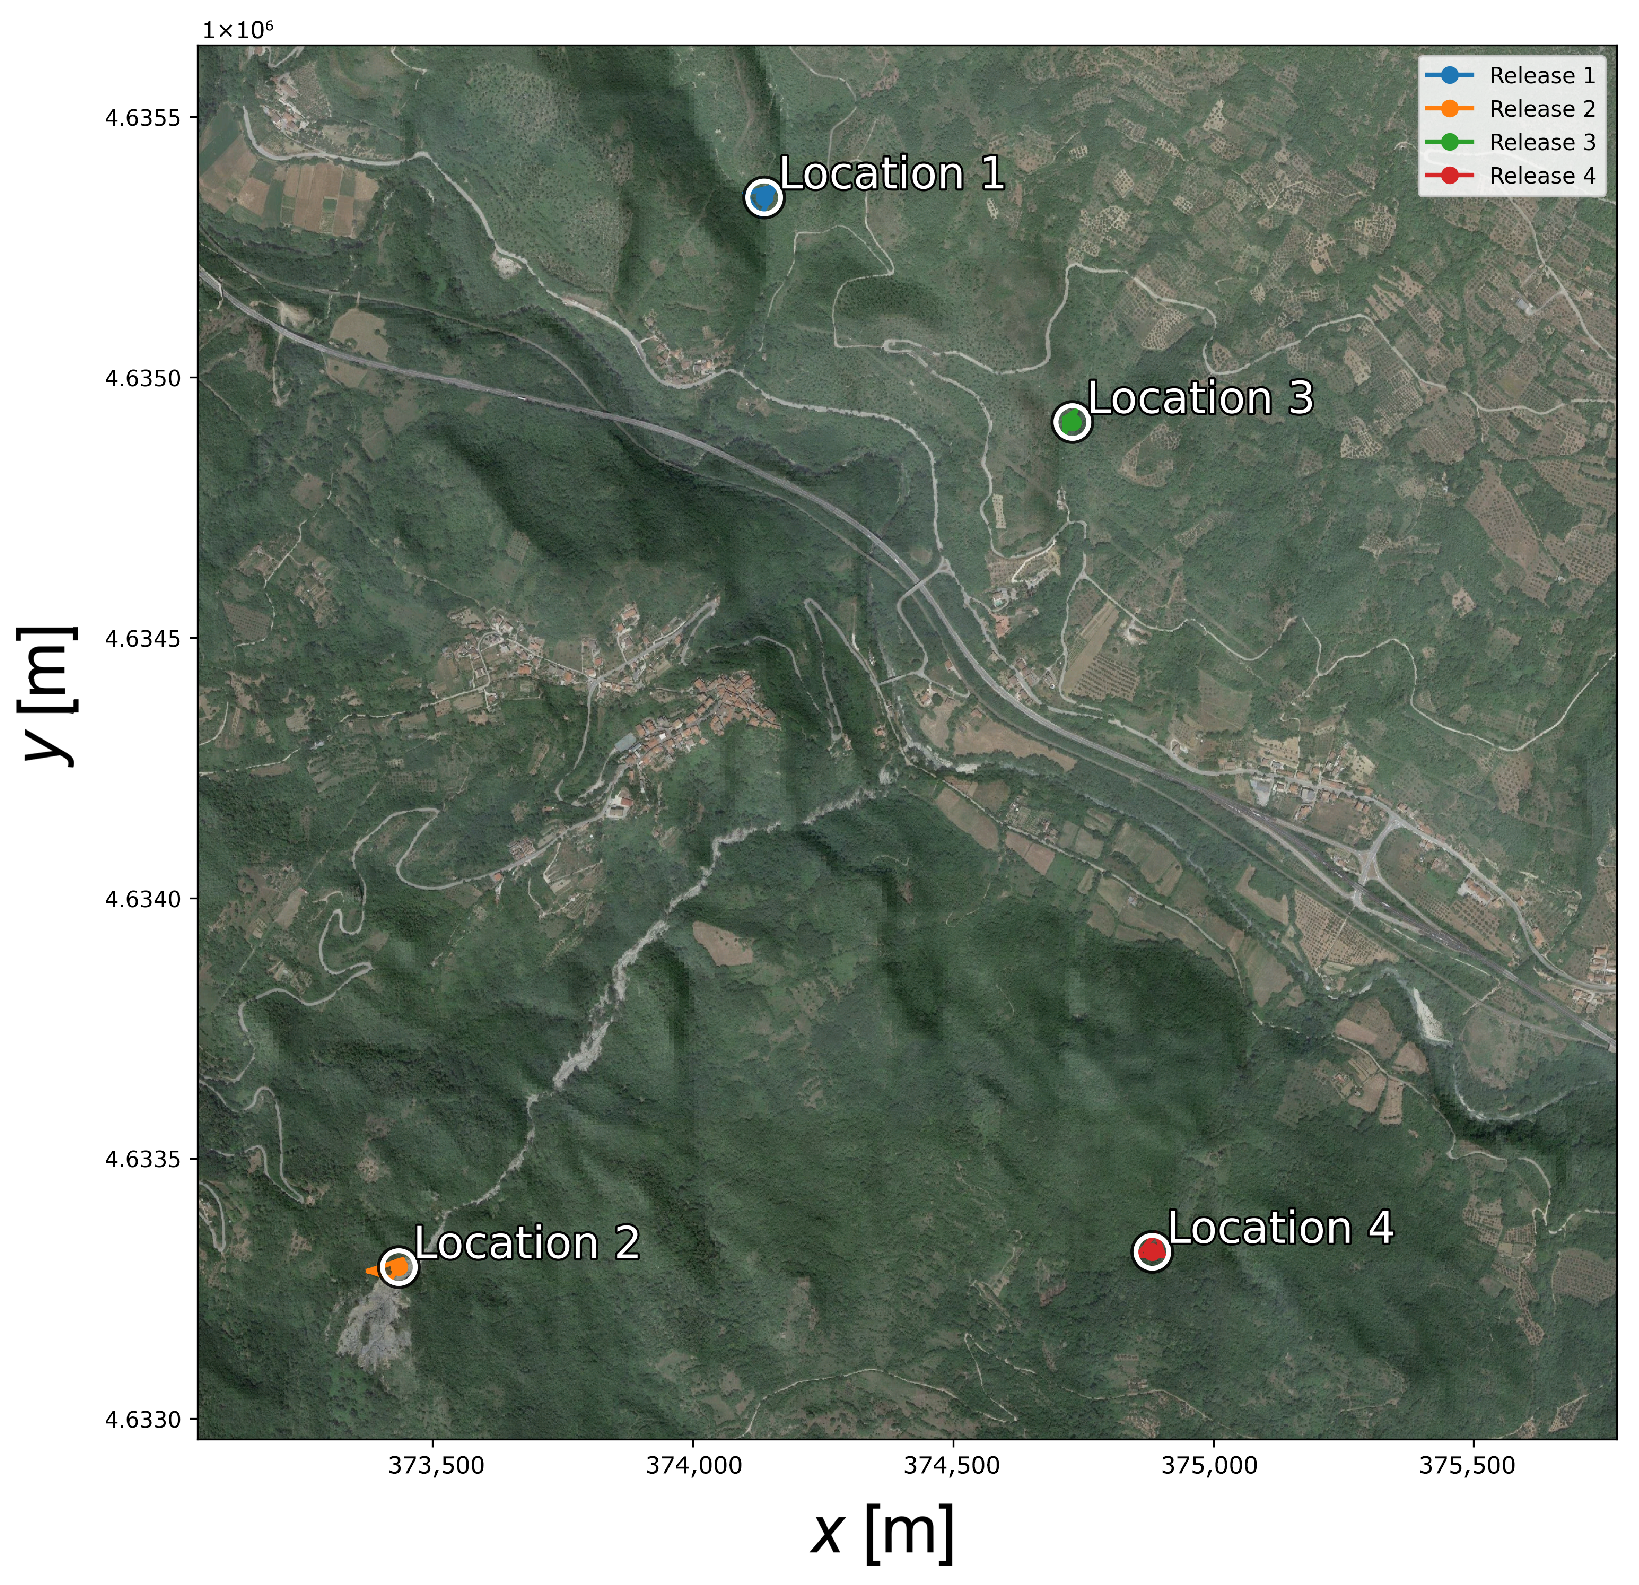
The synthetic dataset was generated by repeatedly solving the debris-flow model on local domains extracted from the Morino–Rendinara area, reproducing the main geomorphological controls of the study area. Four representative release profiles were selected to sample different site-specific conditions (
Figure 2). These four release profiles were chosen to represent different source areas and debris-flow paths in the Morino–Rendinara basin, considering local topography, release geometry, and deposition patterns affecting Rendinara and Morino. Together, they provide a compact but varied set of site-specific scenarios to characterize urban boundaries from a debris-flow hazard perspective, rather than to cover all possible source areas in the basin. Since the training set is produced by our validated numerical solver, the synthetic simulations are not arbitrary realizations, but physically consistent solutions of the adopted debris-flow model under site-specific topographic and rheological conditions.
All simulations were performed on a digital elevation model (DEM) resampled to a 10 m resolution. The governing equations were integrated up to s with the finite-volume solver described above, employing a first-order scheme to limit computational cost, explicit time stepping, and a CFL-based stability criterion. Outputs were stored every 10 s to obtain a time-resolved description of the flow evolution. In order to limit the computational burden, curvature effects and inflow hydrographs were neglected; the simulations therefore represent release-driven propagation governed solely by topography, Voellmy-type basal friction, and erosion–entrainment. One representative finite-volume simulation required approximately 47 s, providing a reference cost for comparison with surrogate inference. The finite-volume simulations used for dataset generation were carried out on Google Colab in a Python 3.12 environment, using a cloud-based runtime equipped with an NVIDIA RTX PRO 6000 Blackwell Server Edition GPU.
The parameter space was kept compact and focused on the main controls on event intensity. The basal-friction parameters were fixed according to the values adopted for the real Morino–Rendinara case, namely
,
, and
, consistently with Pasculli et al. [
6]. In contrast, bulk density and released volume were varied systematically. In particular, the dataset includes different hypothetical release volumes, introduced to represent debris-flow scenarios of increasing magnitude. Larger volumes are expected to produce longer runout distances and greater deposited thicknesses, while different bulk-density values were considered to account for plausible variations in flow inertia. The initial condition of each simulation is defined by the released volume
V and the initial thickness field
. The latter is prescribed within the release polygon, so that the source geometry defines the spatial support of the initial mass, while the hypothetical release volume controls its magnitude. Boundary conditions were kept fixed throughout the campaign and coincide with those of the numerical solver: an open-domain treatment was adopted, and no external inflow was prescribed. Four release settings were considered. For each of them, simulations were generated by combining five bulk-density values,
and
, with five hypothetical release volumes equal to
and
. This produced 25 simulations for each release setting and 100 simulations in total. For the present site-specific objective, this 100-sample dataset was considered adequate because it systematically covers the four release profiles of interest and the main volume–density combinations controlling event magnitude.
A summary of the main simulation parameters is reported in
Table 1.
Figure 2 summarizes the spatial distribution of the four release settings within the Morino–Rendinara area. The dataset therefore does not rely on a single terrain configuration, but samples multiple site-specific propagation contexts.
For each simulation, solver outputs were converted into train-ready tensors. The stored channels include topography, basal-friction maps, time-dependent flow variables, and bulk density as conditioning information. Since the local domains differ in spatial extent, all samples were padded to a common tensor size and stored. The train–validation split was performed with a balanced procedure to ensure that all release settings were represented in both subsets. A validation fraction of
was adopted, together with a fixed random seed for reproducibility. A summary of the dataset characteristics is reported in
Table 2.
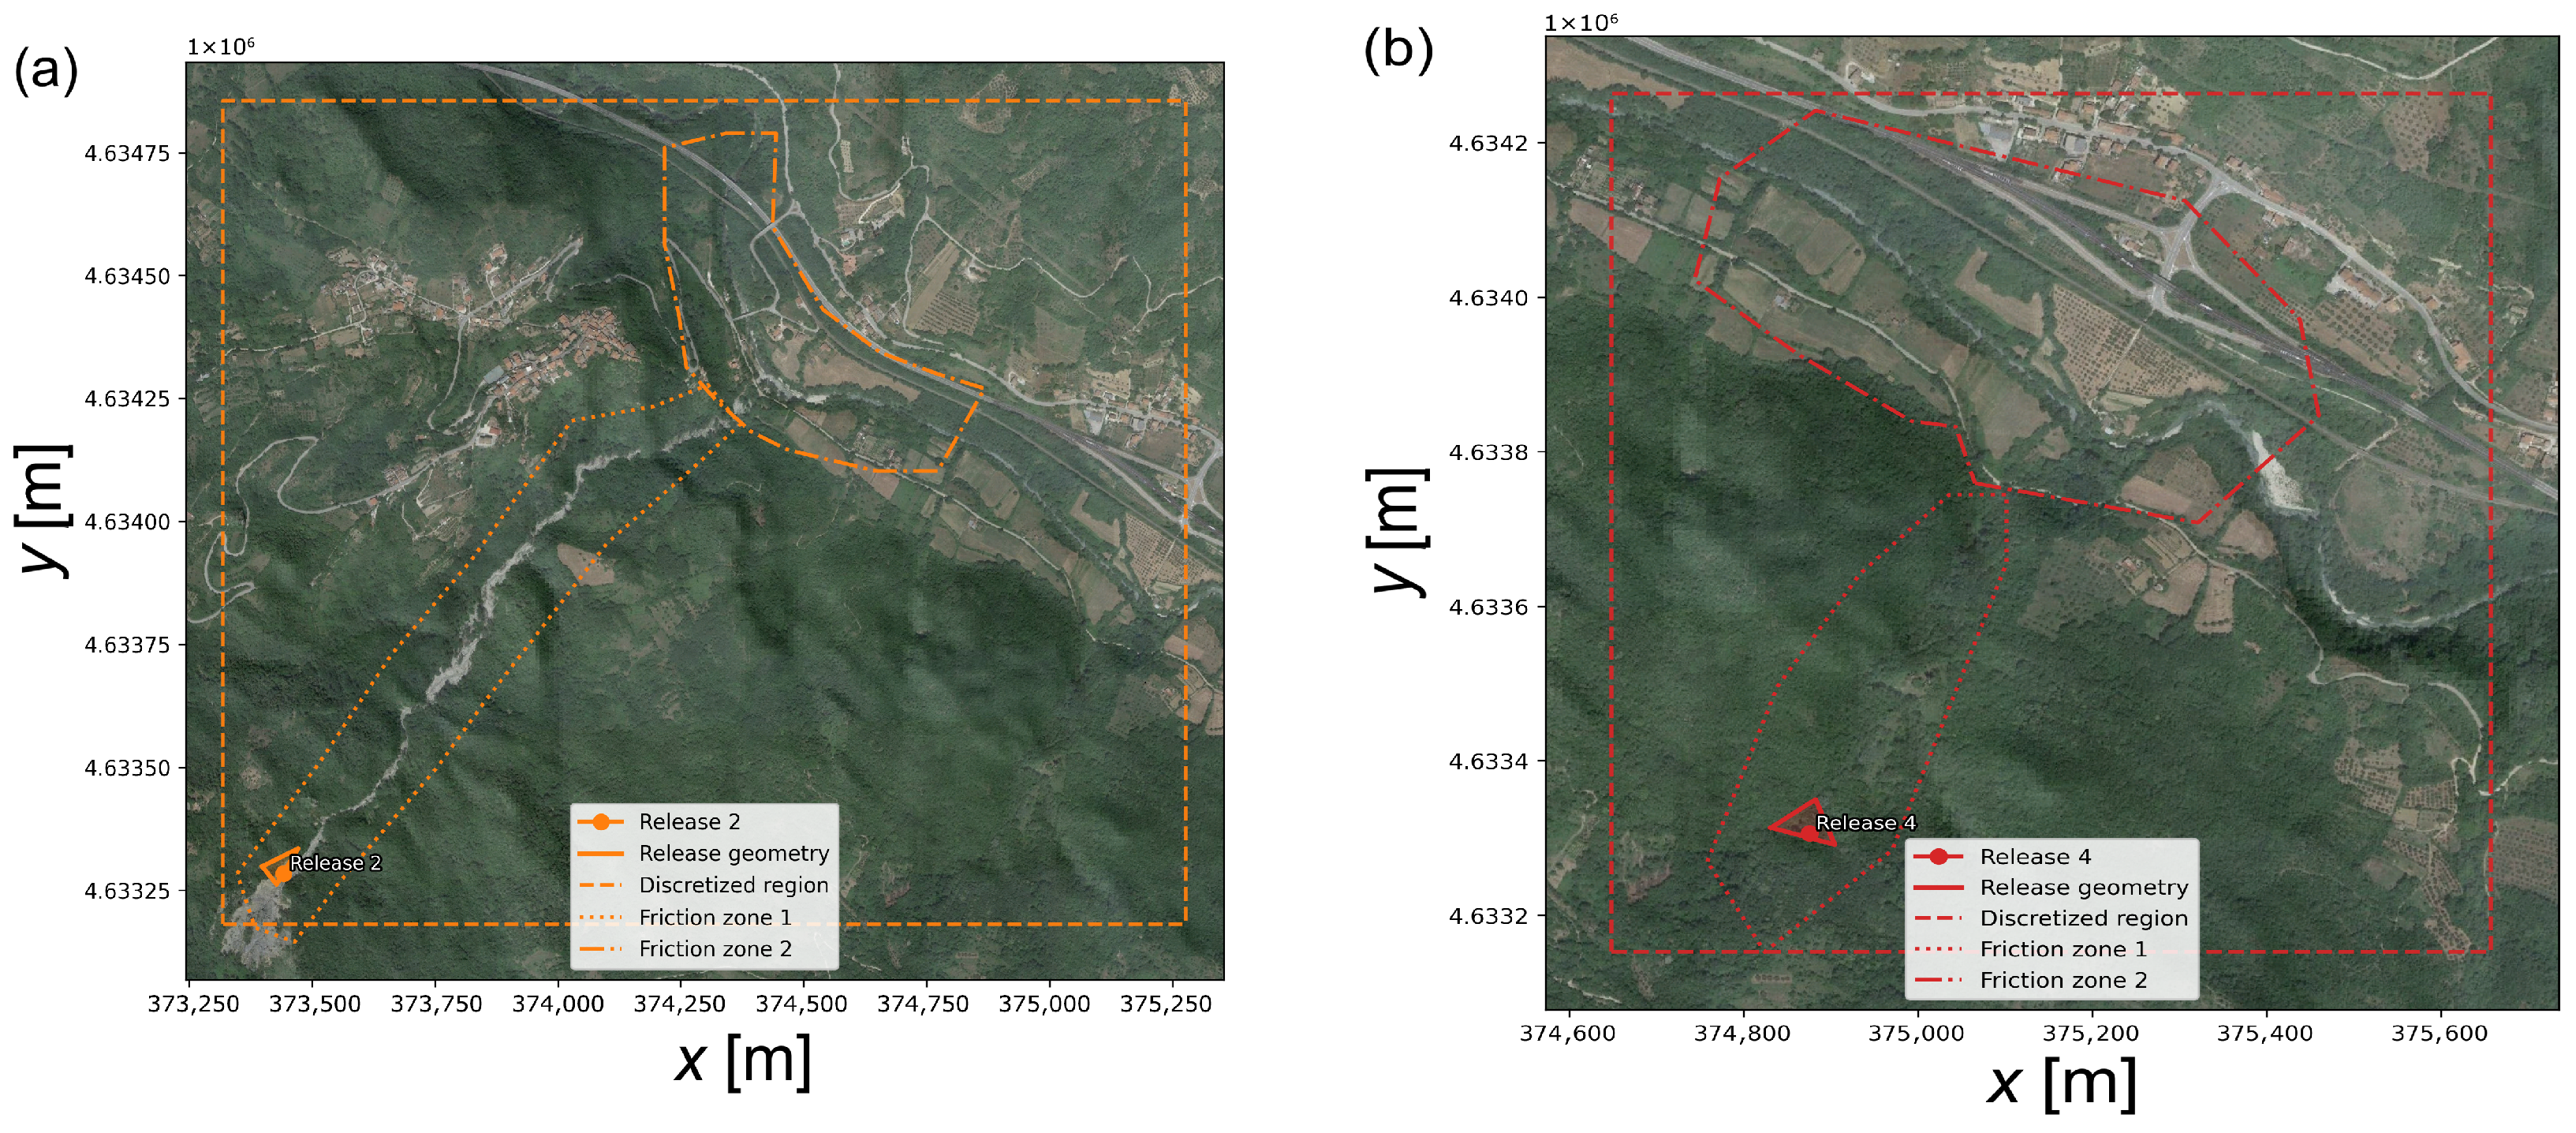
To clarify the internal organization of the dataset, two representative release settings are discussed in more detail: Release 2 and Release 4. These correspond to two of the four release profiles adopted in the synthetic campaign.
Figure 3 shows the orthophoto-based configuration of the two selected profiles. In each case, the maps identify the release location, the release polygon, the clipping window used to define the local computational domain, and the two friction polygons adopted to represent the spatial variability of basal resistance in the Morino–Rendinara area. Each release scenario is therefore defined not only by a source location, but also by a specific domain geometry and friction zoning.
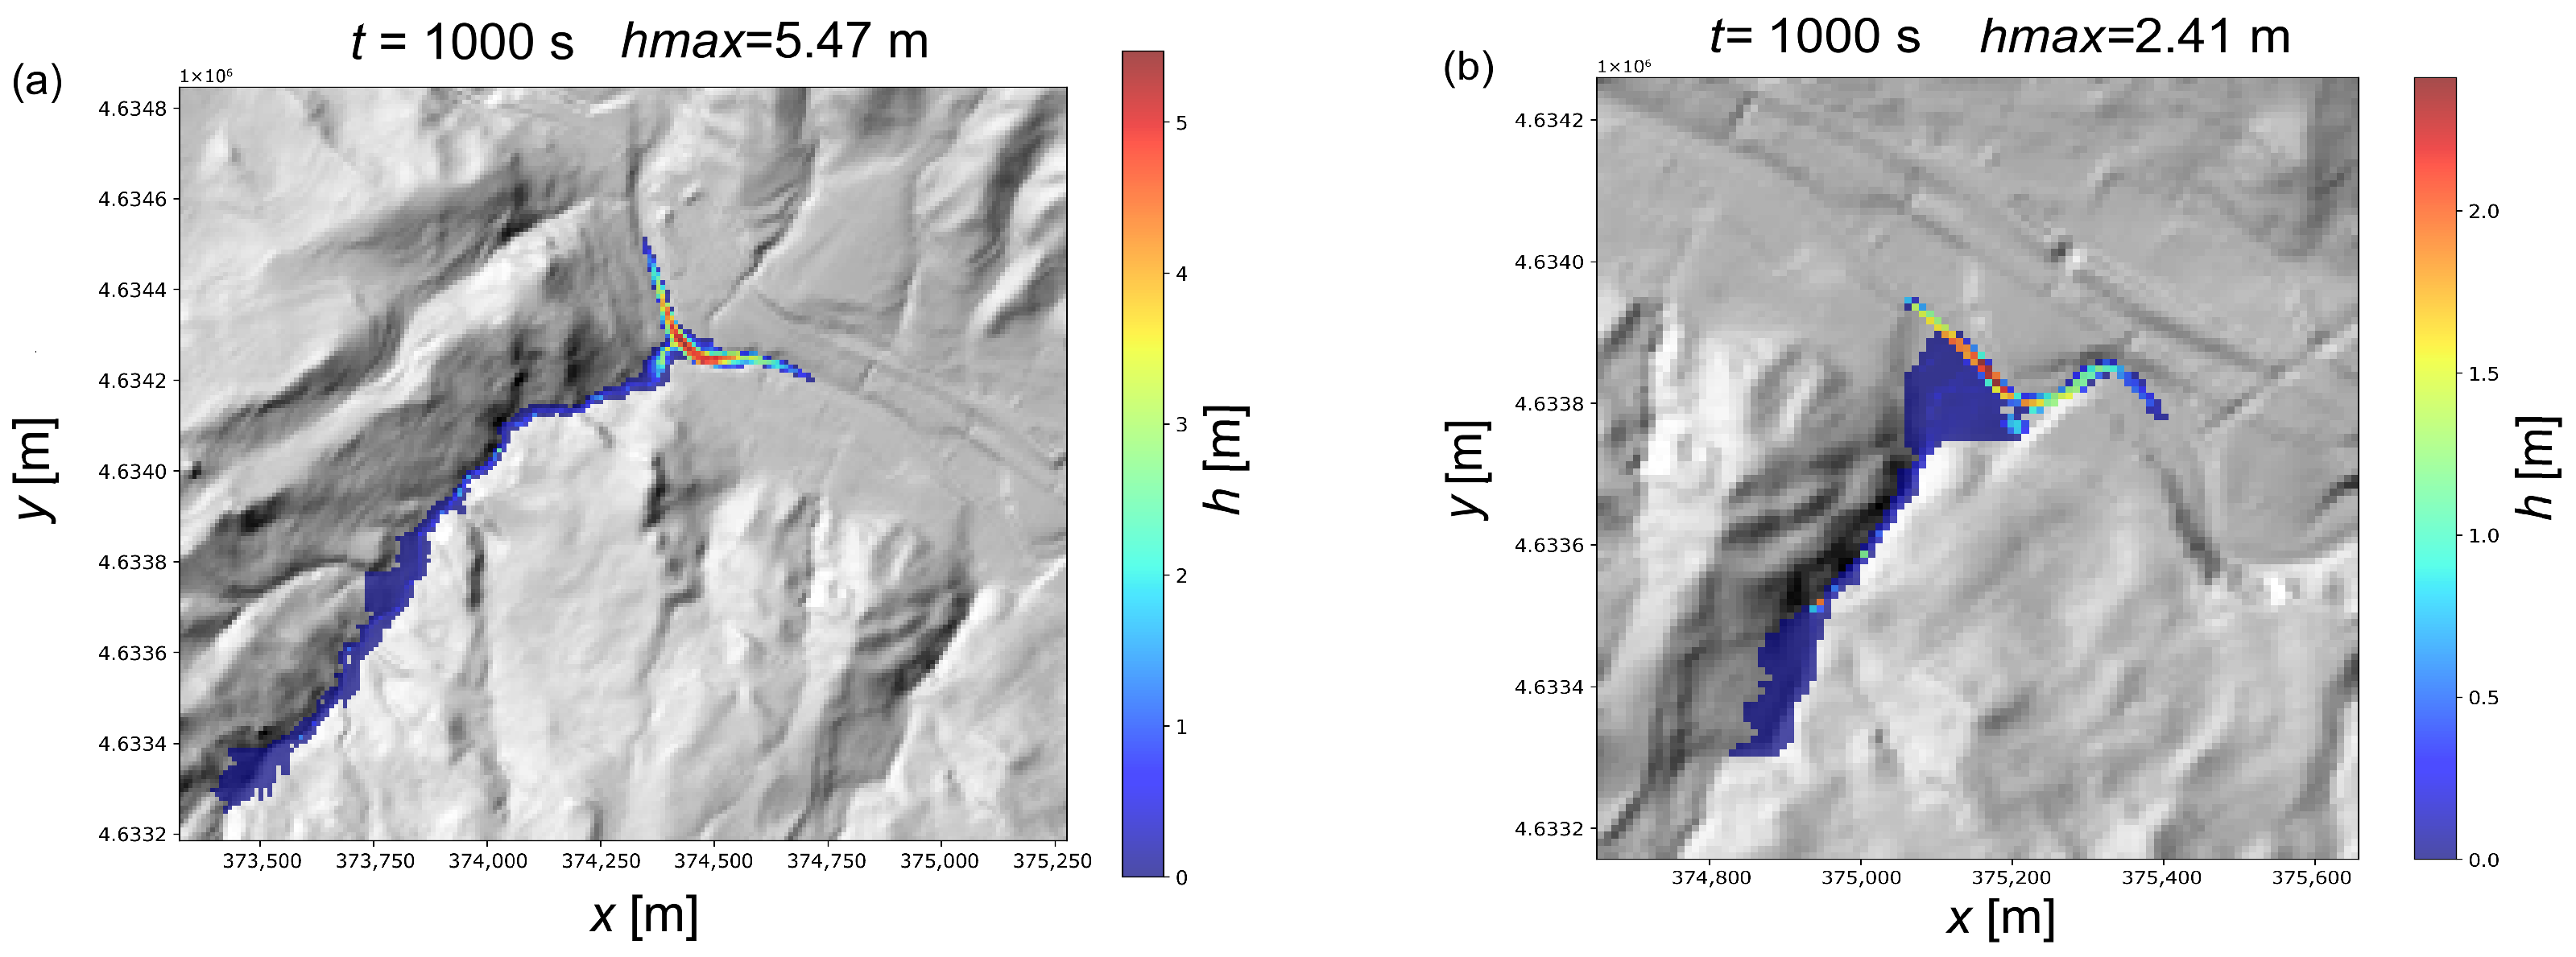
To complement the geometric description, two representative simulations are shown for the same release settings.
Figure 4 reports the final simulation frames at
for Release 2 and Release 4, for virtual released volumes of
and
, respectively.
The plotted variable is the final flow thickness
h, superimposed on the local hillshade topography. These examples illustrate the type of spatio-temporal output stored in the dataset. Although the simulations share the same numerical framework, the resulting runout and deposition patterns differ because of the different local topography, release geometry, and friction zoning associated with each profile. Only the final flow-thickness field
h is shown here, although the solver also provides the 2D velocity components
u and
v for each simulation output; these are analyzed in greater detail in
Section 4.
3.4. Fourier Neural Operator
The FNO is an AI-based method that has emerged as an effective architecture for learning mappings between function spaces arising in physical systems [
38,
40]. Instead of approximating a single solution for a fixed configuration, neural operators learn an operator that maps input functions, such as parameters, geometry, or initial conditions, to the corresponding solution fields.
In the context of debris-flow modelling, the objective is to learn the nonlinear operator
where
represents the set of input fields and conditioning parameters (e.g., topography, rheological parameters, and initial conditions), and
denotes the resulting flow variables predicted by the model. Similar ideas have recently been explored in debris-flow applications [
41], where deep learning was used to approximate the dynamics generated by shallow-flow numerical solvers.
The key idea of the FNO is to perform the learning process in the spectral domain. By operating in the Fourier domain, the model can capture long-range spatial interactions with a reduced number of spectral coefficients, which is particularly advantageous for fluid-dynamical and geophysical flow problems [
33,
38,
40].
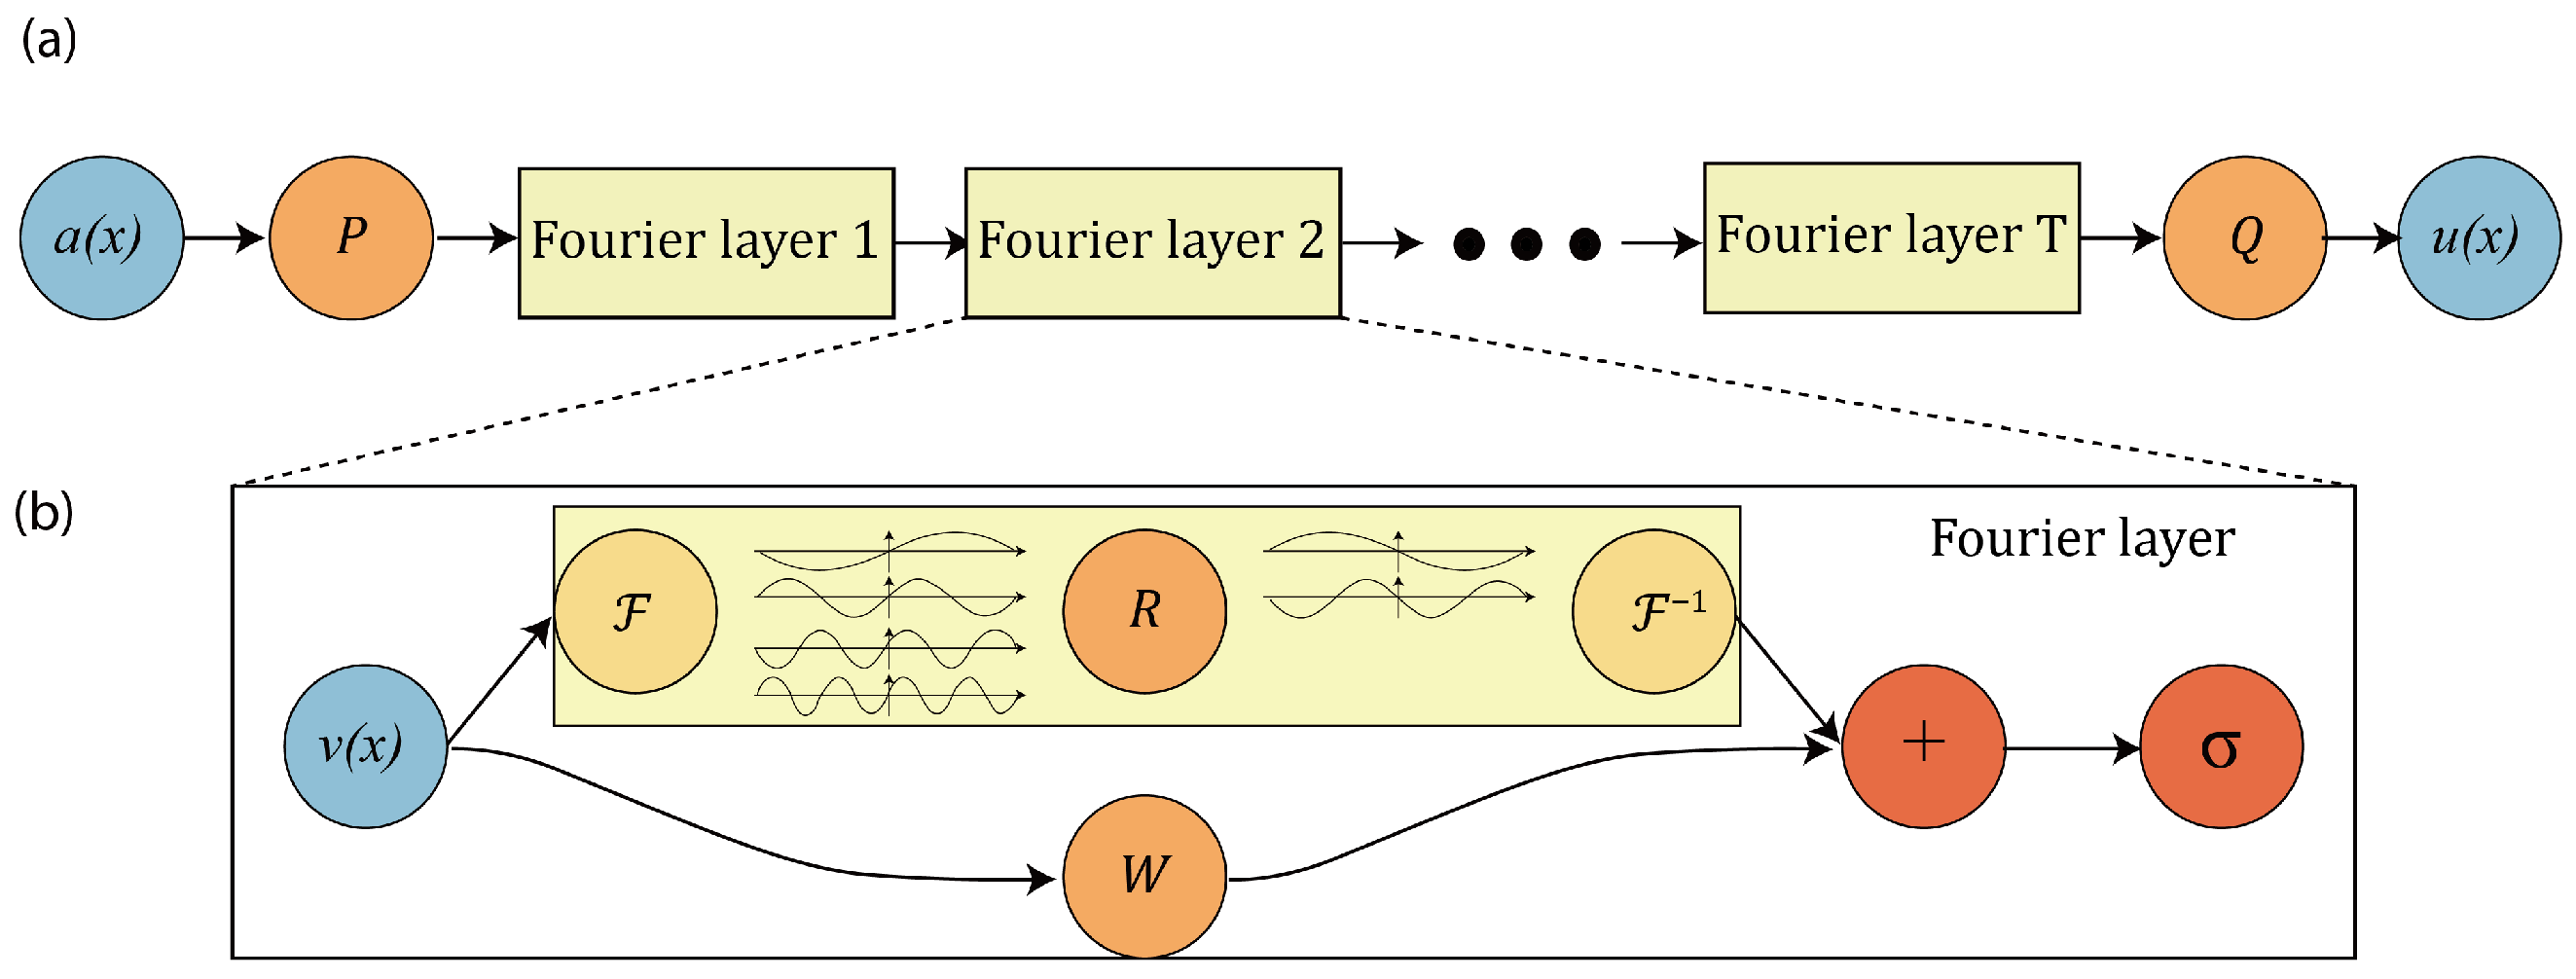
Figure 5 [
38] illustrates the structure of the FNO used in this work.
Figure 5a shows the overall architecture: the input function
is first mapped to a higher-dimensional representation through a lifting operator
P, then processed through multiple Fourier layers, and finally projected back to the physical variables
through a projection operator
Q.
Figure 5b shows the internal structure of a Fourier layer, where the feature maps are transformed into Fourier space, modified by learnable spectral weights, and combined with a local linear transformation before the nonlinear activation.
Once trained, the FNO provides a fast surrogate of the numerical solver, capable of predicting the spatio-temporal evolution of the debris-flow fields for new input configurations. This capability makes neural operators particularly attractive for large ensemble simulations, uncertainty propagation, and rapid scenario analysis in debris-flow hazard assessment.
3.5. Training Procedure and Model Optimization
The FNO was trained to approximate the nonlinear mapping between the spatio-temporal fields defining each synthetic debris-flow scenario and the corresponding evolution of the simulated flow variables. In the present dataset, each sample is stored as a tensor of shape , where the seven channels correspond to the basal friction coefficient , the turbulent friction parameter , the bulk density , the bed elevation , the flow thickness h, and the two depth-averaged velocity components u and v.
Starting from these fields, the input tensor of the neural operator is constructed by combining normalized coordinates with the physical conditioning variables. More precisely, the network input is defined as
where
denotes the initial flow thickness, replicated along the temporal dimension. The network target is instead given by
Therefore, the model learns the full spatio-temporal evolution of the depth and velocity fields from the geometric, rheological, and initial-condition descriptors of the problem.
A summary of input and output variables used for FNO training is reported in
Table 3.
Before training, channel-wise normalization statistics were computed using only the training subset. The normalization was applied separately to the physical input channels and to the output channels , whereas the coordinates were already expressed in normalized form in the interval . Means and standard deviations were estimated globally over the valid cells of the training samples only, so that padded regions did not influence the statistics. The same normalization parameters were then used consistently for both training and validation data.
The surrogate model is a 3D FNO
acting jointly on the two spatial coordinates and on time. The network receives tensors of shape
where
B denotes the batch size, and returns tensors of shape
The architecture first lifts the eight-dimensional input into a latent feature space of width 96 through a fully connected layer. The latent representation is then processed by three consecutive Fourier blocks, a choice based on initial tuning experiments and practical GPU memory constraints, and retained as a sufficiently expressive and stable compromise between predictive accuracy, computational cost, and training robustness. Each block combines a spectral convolution in the domain with a pointwise convolution, followed by a Gaussian Error Linear Unit (GELU) activation function. In the spectral branch, only a truncated set of Fourier modes is retained, namely 16 modes along each spatial direction and 12 modes along the temporal direction. After the sequence of Fourier blocks, the latent representation is projected back to the physical output space by means of two fully connected layers, with an intermediate projection dimension equal to 160. In order to reduce edge artefacts during the spectral operations, a padding of five cells is applied before the Fourier blocks and removed after the spectral processing. The model parameters were optimized using the Adam algorithm with an initial learning rate equal to and weight decay equal to . Training was performed for 100 epochs with a batch size equal to 1 for both training and validation. The learning rate was updated through a multi-step scheduler, with decay milestones at epochs 60 and 80 and multiplicative factor . At the end of each epoch, the model was evaluated on the validation set, and the best-performing checkpoint was selected according to the minimum validation loss.
A standard training loss, such as mean squared error, mean absolute error, or Huber loss, can be dominated by the many dry or nearly dry cells present in each simulation. As a result, it may achieve effective overall accuracy while still under-resolving the advancing front and the sparse regions with active flow. To address this issue, the training objective was defined as a task-specific masked loss designed to exclude padded cells, emphasize active-flow regions, and assign greater importance to velocity reconstruction. In the main text, we report only the global form of the objective function, while the detailed definitions of the channel-wise loss terms are provided in
Appendix A.4.
Accordingly, the total training loss is written as
with
The detailed formulation of
,
, and
, including the masking and weighting strategy adopted for active-flow regions and padded cells, is reported in
Appendix A.4. This choice was introduced to assign greater importance to the reconstruction of the velocity field, which is generally more difficult to learn and more sensitive to localized discrepancies near the advancing front and in low-thickness regions [
41].
During training, the trend of the total loss and of the individual channel-wise contributions was stored for both training and validation. In addition, model checkpoints, optimizer state, scheduler state, and normalization parameters were periodically saved in order to ensure reproducibility and restart capability. At the end of the optimization process, both the final model and the model achieving the minimum validation loss were exported and retained for subsequent evaluation.
The model was trained in the same Google Colab computing environment used for finite-volume simulations and dataset generation, with Python 3.12, using a cloud-based runtime equipped with an NVIDIA RTX PRO 6000 Blackwell Server Edition GPU. The total training time was approximately 2 h 30 min.
A summary of the architecture, loss weighting, optimization, and training setup of the 3D FNO adopted in this work is reported in
Table 4.
4. Results
4.1. Training Dynamics and Validation Errors
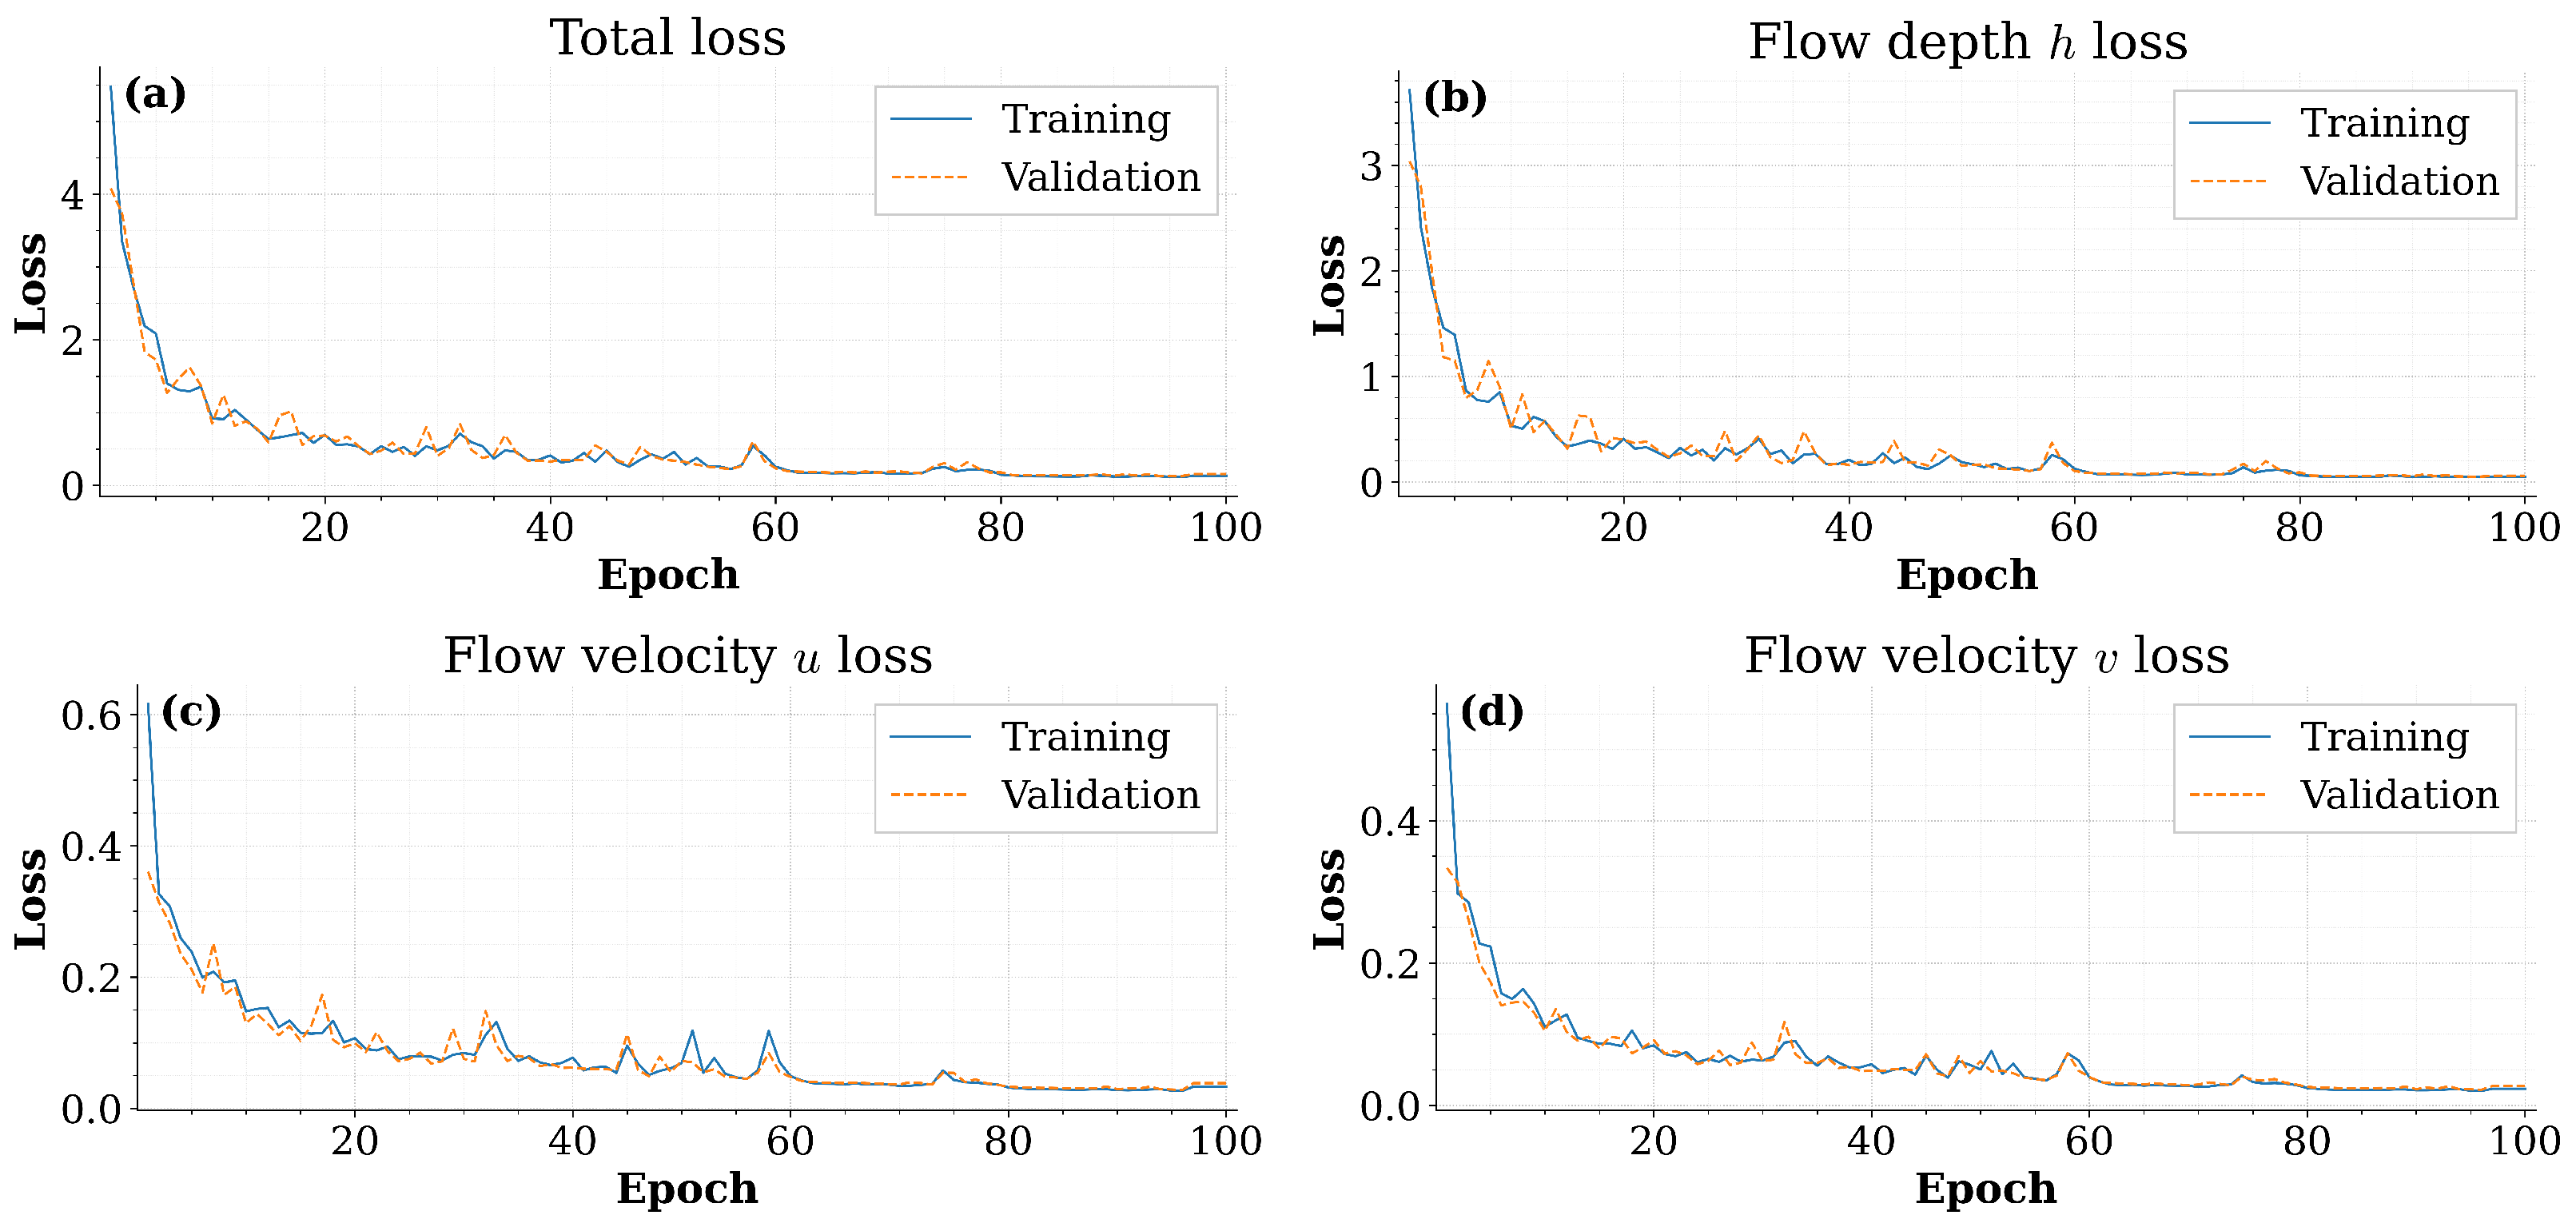
The training and validation loss trends for the total objective function, flow thickness
h, and velocity components
u and
v are shown in
Figure 6. Overall, the optimization process exhibits stable convergence over the 100 training epochs. All loss terms decrease rapidly during the initial epochs, followed by a slower decay toward convergence.
A close agreement between training and validation curves is observed for all monitored quantities. This behaviour indicates satisfactory generalization to within-distribution validation samples and no significant overfitting.
For the quantitative assessment, model performance was evaluated using the masked mean squared error (MSE) and the relative masked mean squared error (rMSE), both computed over the valid spatio-temporal support of each sample [
45,
46].
At the dataset level, the validation results confirm the overall robustness of the model. The mean relative mean squared error is 5.49% for the flow thickness
h, 5.34% for the longitudinal velocity
u, and 2.60% for the transverse velocity component
v. The corresponding average coefficients of determination are
,
, and
, respectively. Overall, the surrogate reconstructs all three target fields with significant accuracy on the validation set, with particularly strong performance for the transverse velocity component
v, which shows the lowest relative error and the highest
. Although the absolute MSE values reported in
Table 5 are larger for the velocity components than for flow thickness, this does not imply worse normalized reconstruction accuracy, since
h,
u, and
v differ in physical units, characteristic magnitude, and spatial variability. This is confirmed by the relative MSE values, which are very similar for
h and
u (5.49% and 5.34%, respectively) and lower for
v (2.60%), indicating that the normalized reconstruction of the transverse velocity component is, overall, more accurate. In addition, the difference between
u and
v likely reflects their different morphodynamic roles within the flow, with
u more directly associated with channelized downslope propagation and localized acceleration along the main flow path, and
v more influenced by lateral spreading, local curvature, and channel widening or narrowing. In practical terms, these error values indicate that the surrogate model reproduces the target fields with solid accuracy on the validation set. The corresponding quantitative metrics are summarized in
Table 5.
To complement the aggregate validation metrics reported in
Table 5, which summarize the mean performance over the full validation set,
Table 6 presents the corresponding sample-wise validation results for all validation samples at the final simulation time. This more detailed view makes it possible to assess not only the overall average behaviour of the surrogate, but also the spread of errors across individual cases, including the less accurate and more demanding samples. In particular, the relative mean squared error ranges from 0.54% to 11.15% for
h, from 1.39% to 9.46% for
u, and from 1.62% to 3.63% for
v, with corresponding
values ranging from 0.86 to 0.99, 0.90 to 0.98, and 0.96 to 0.98, respectively. These results indicate that the transverse velocity component
v is reconstructed more consistently across the full validation set, whereas the largest sample-to-sample variability is observed for flow thickness
h and, to a lesser extent, for the longitudinal velocity
u.
In addition to predictive accuracy, the surrogate also provides a substantial reduction in computational cost at inference time. For a representative validation sample, the trained FNO required only
s to predict the full spatio-temporal solution, whereas the corresponding numerical simulation performed with the first-order finite-volume solver on the same 10 m DEM required approximately 47 s. Both timings therefore refer to the same Google Colab computing environment, avoiding a comparison between different hardware configurations. This corresponds to a speed-up factor of about
compared with the first-order finite-volume solver (
Table 7).
4.2. Final Flow-Depth Maps for Representative Validation Samples
To complement the aggregate validation metrics reported in
Section 4.1, the surrogate was further analyzed on three representative validation samples: sample_000029 (released volume 750 m
3), sample_000079 (released volume 750 m
3), and sample_000045 (released volume 1000 m
3). These cases were selected to compare different local release settings and to highlight different levels of reconstruction difficulty, including the most challenging validation case for the final flow-depth field
h.
Table 8 summarizes the sample-wise validation errors for the final flow thickness field
h. For sample_000029, the relative mean squared error is
with
, whereas for sample_000079 the relative mean squared error is
with
. By contrast, sample_000045 yields a relative mean squared error of
with
, and therefore represents the most demanding validation case for the final flow-depth field among the validation samples. These results indicate that the surrogate reconstructs the final flow thickness with very effective accuracy in the first two cases, while sample_000045 provides a useful example of a more challenging prediction setting.
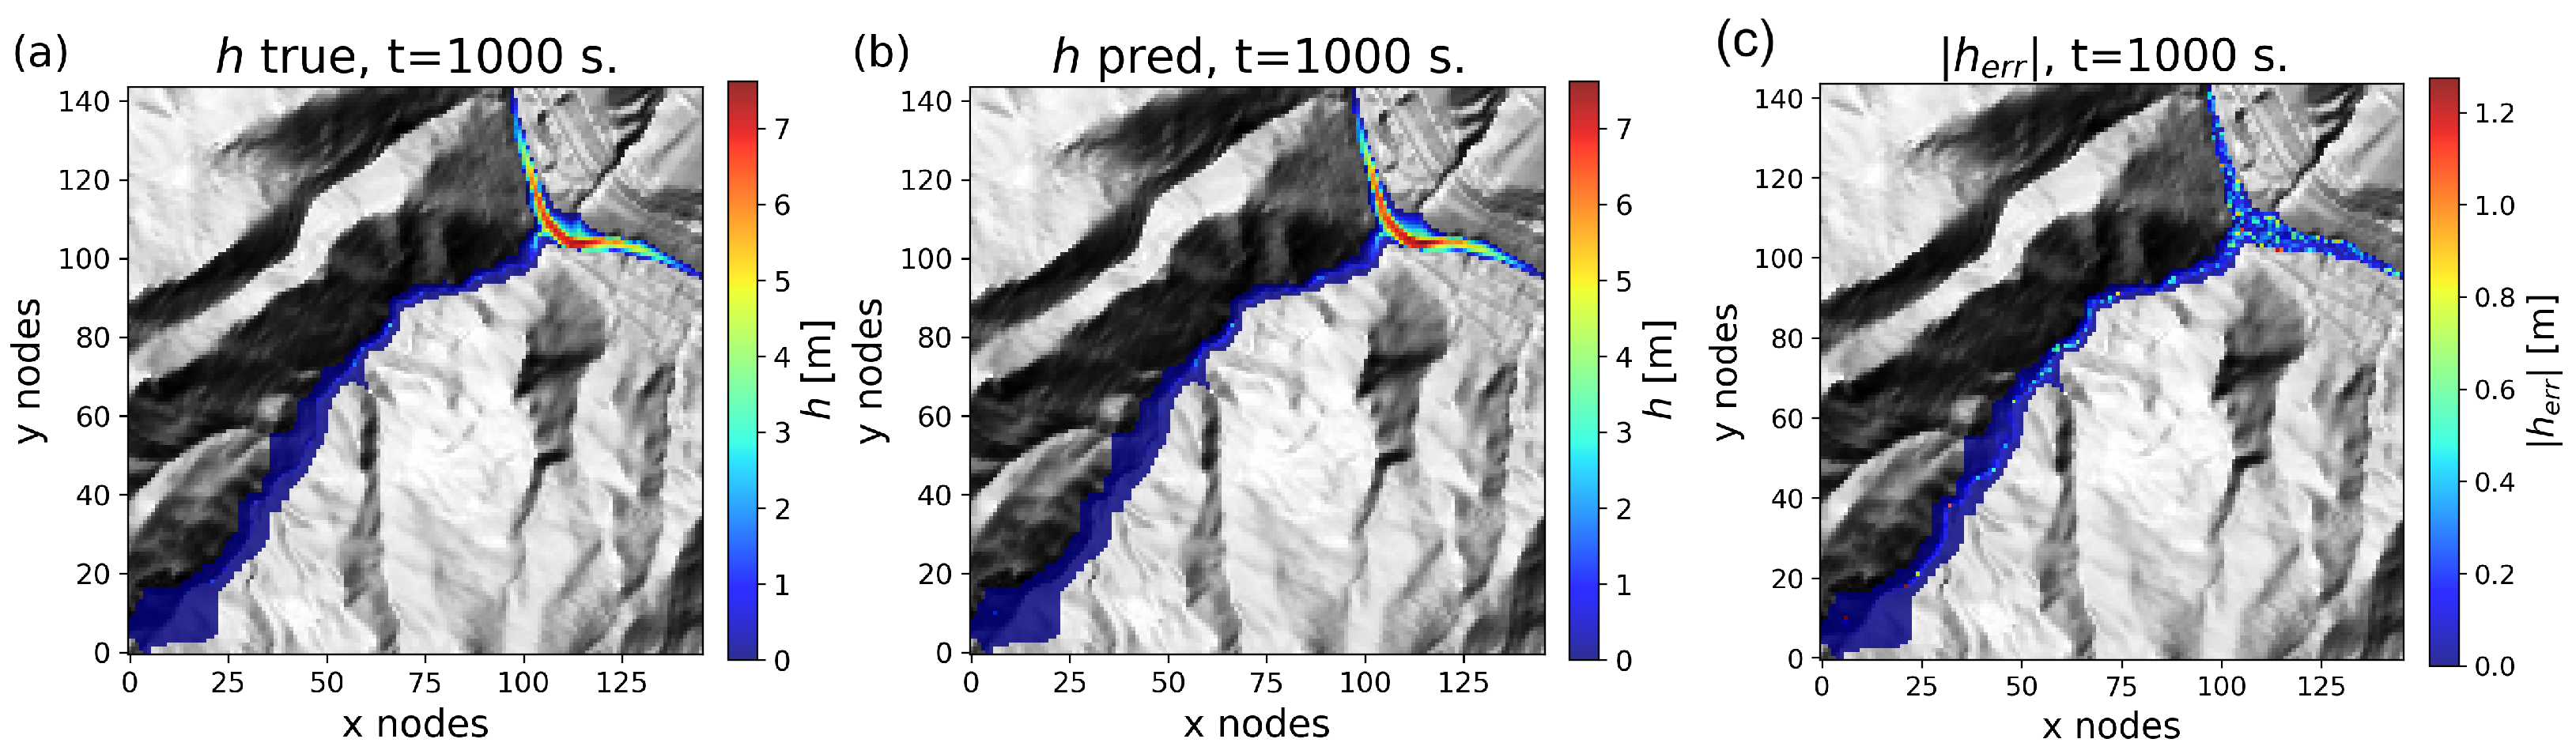
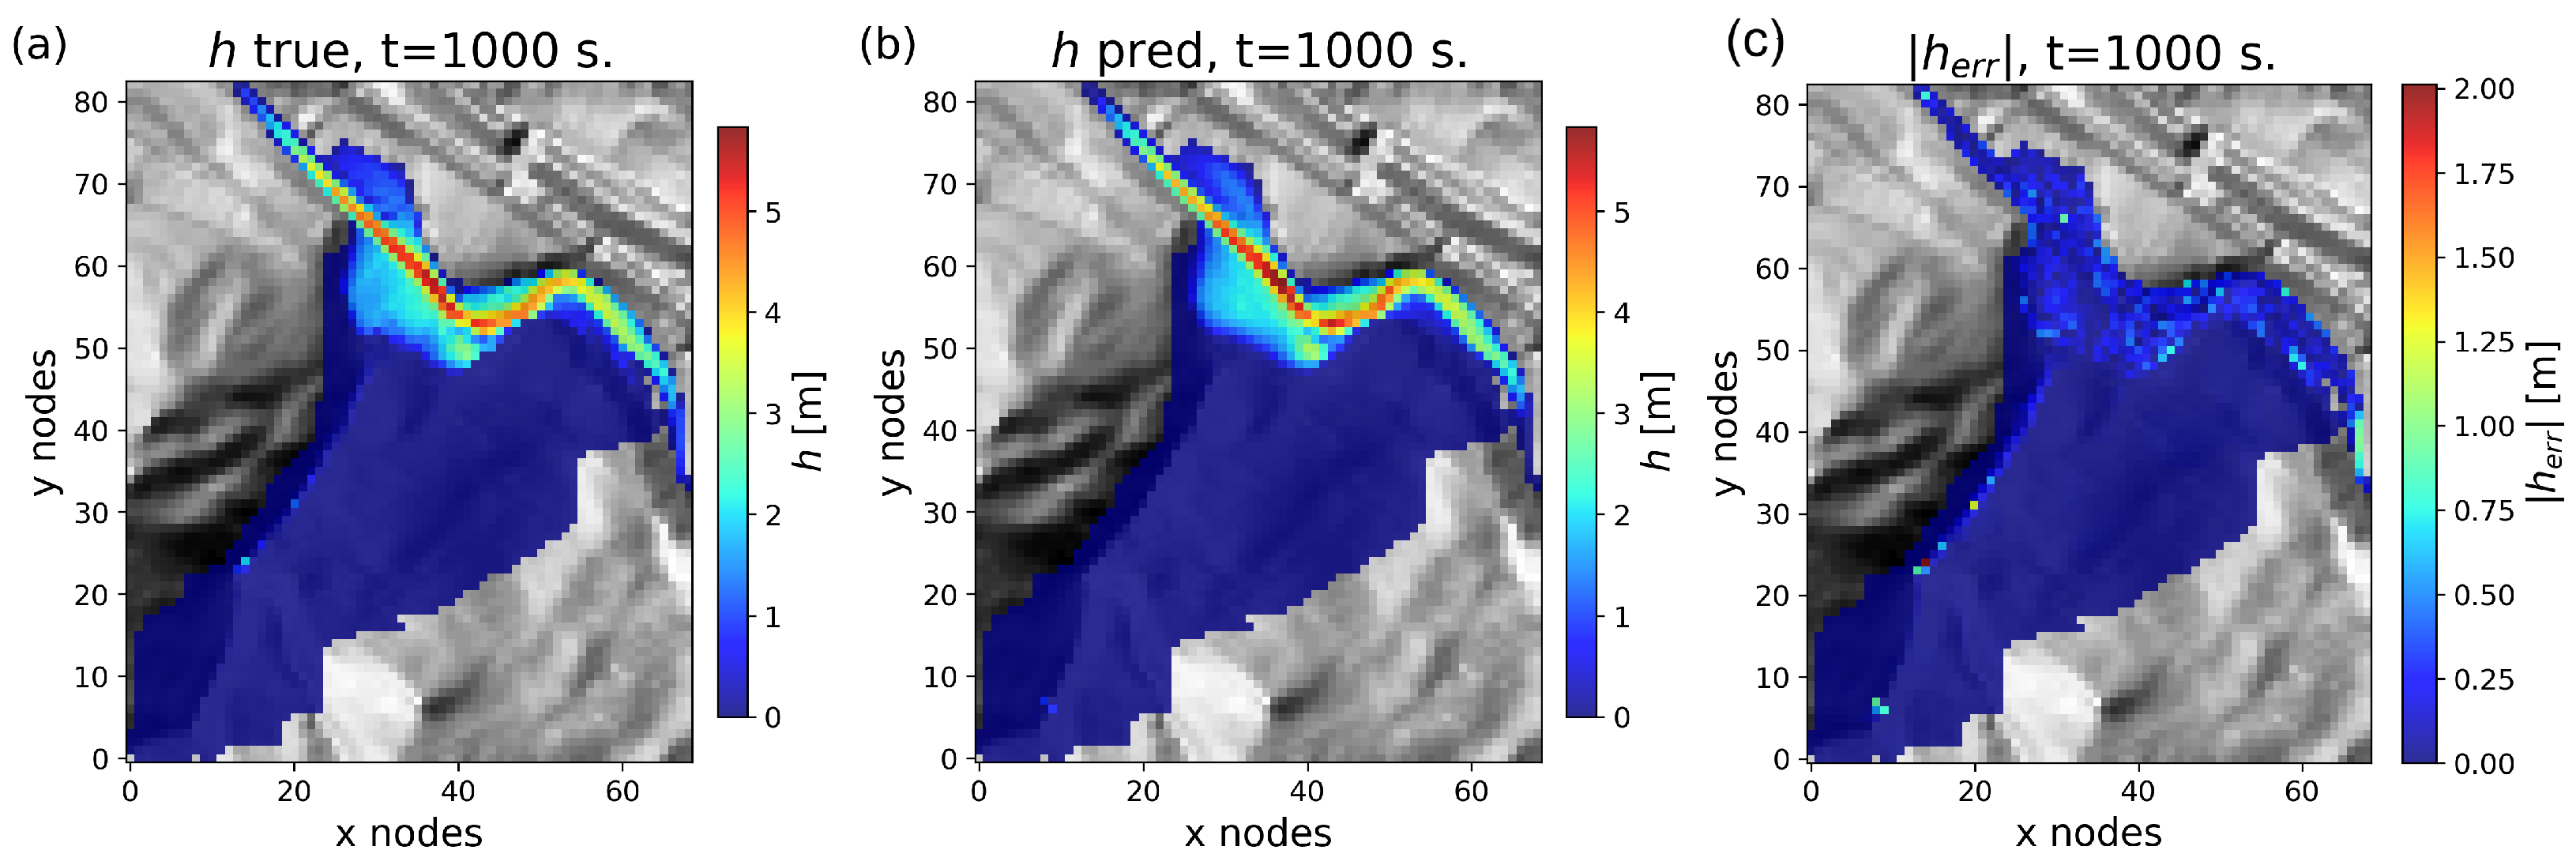
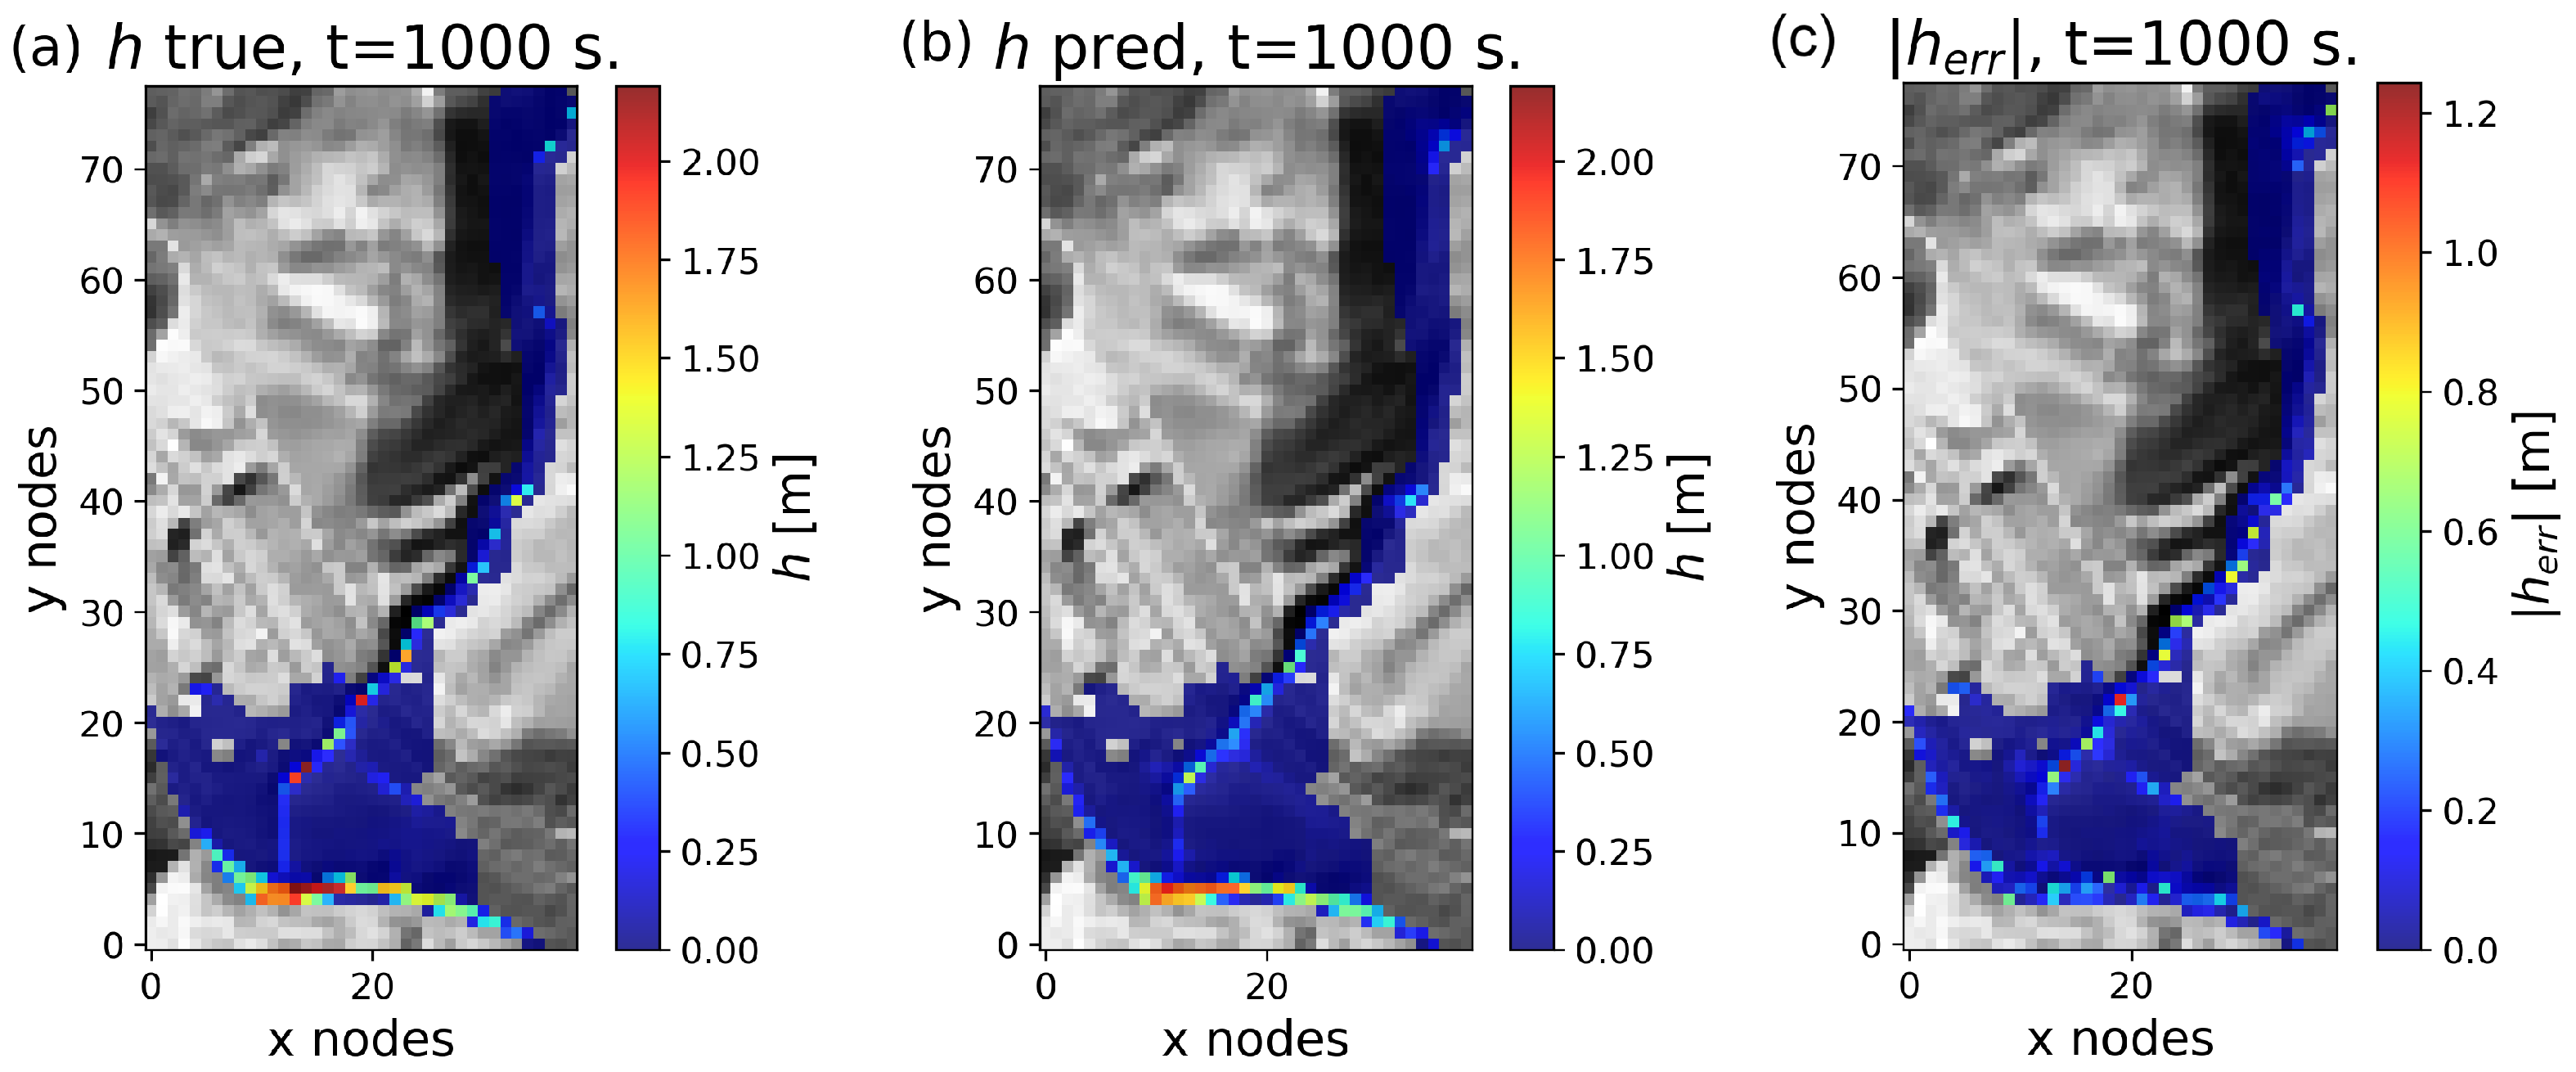
Figure 7,
Figure 8 and
Figure 9 compare the reference and predicted final flow thickness
h for the three validation samples. For sample_000029 and sample_000079, the surrogate accurately reproduces the deposit footprint, the main depositional corridor, and the location of the maximum thickness values. The predicted fields are also consistent with the reference in terms of amplitude along the main flow path, and no significant large-scale discrepancies are observed. For sample_000045, the predicted field still captures the overall deposit footprint and the main channelized runout pattern, but with more pronounced discrepancies in thickness amplitude and along the active depositional sectors, consistently with its larger error metrics.
These maps also show that the model captures the terrain-controlled propagation pattern of the flow. Across the three samples, the predicted thickness follows the main channelized runout and reproduces the main branching structure of the deposit. This suggests that the surrogate preserves the physically meaningful organization of deposition induced by topographic confinement and local spreading, even in the more challenging sample_000045, although with reduced local accuracy.
The absolute error fields shown in panel (c) of
Figure 7,
Figure 8 and
Figure 9 indicate that the largest discrepancies are localized along the active flow corridor, near depositional peaks, and around the wet–dry transition zone. These are also the regions with the strongest local gradients, where small positional offsets can generate visible pointwise errors. In sample_000045, these discrepancies are more pronounced and spatially more extensive, especially along the main depositional front and the curved runout corridor, which explains its larger relative error.
4.3. Final Velocity-Field Reconstruction for Representative Validation Samples
The reconstruction of the velocity components was analyzed separately for the same three representative validation samples, sample_000029 (released volume 750 m3), sample_000079 (released volume 750 m3), and sample_000045 (released volume 1000 m3). Compared with the flow thickness, the velocity fields are more challenging to predict, because they are more sensitive to local acceleration, channel curvature, wet–dry transitions, and topographic forcing. Nevertheless, the surrogate retains significant predictive skill for both components.
Table 9 reports the sample-wise validation metrics for the longitudinal velocity
u and the transverse velocity component
v. For sample_000029, the surrogate achieves a relative mean squared error of
and
for
u, and
with
for
v. For sample_000079, the reconstruction of the velocity field is more demanding, especially for the longitudinal component
u, for which the relative mean squared error increases to
and the coefficient of determination decreases to
. The transverse component
v remains more accurate, with a relative mean squared error of
and
. For sample_000045, the reconstruction becomes substantially more demanding, particularly for the longitudinal velocity component
u, for which the relative mean squared error rises to
and the coefficient of determination decreases to
. The transverse component
v remains comparatively more robust, with a relative mean squared error of
and
.
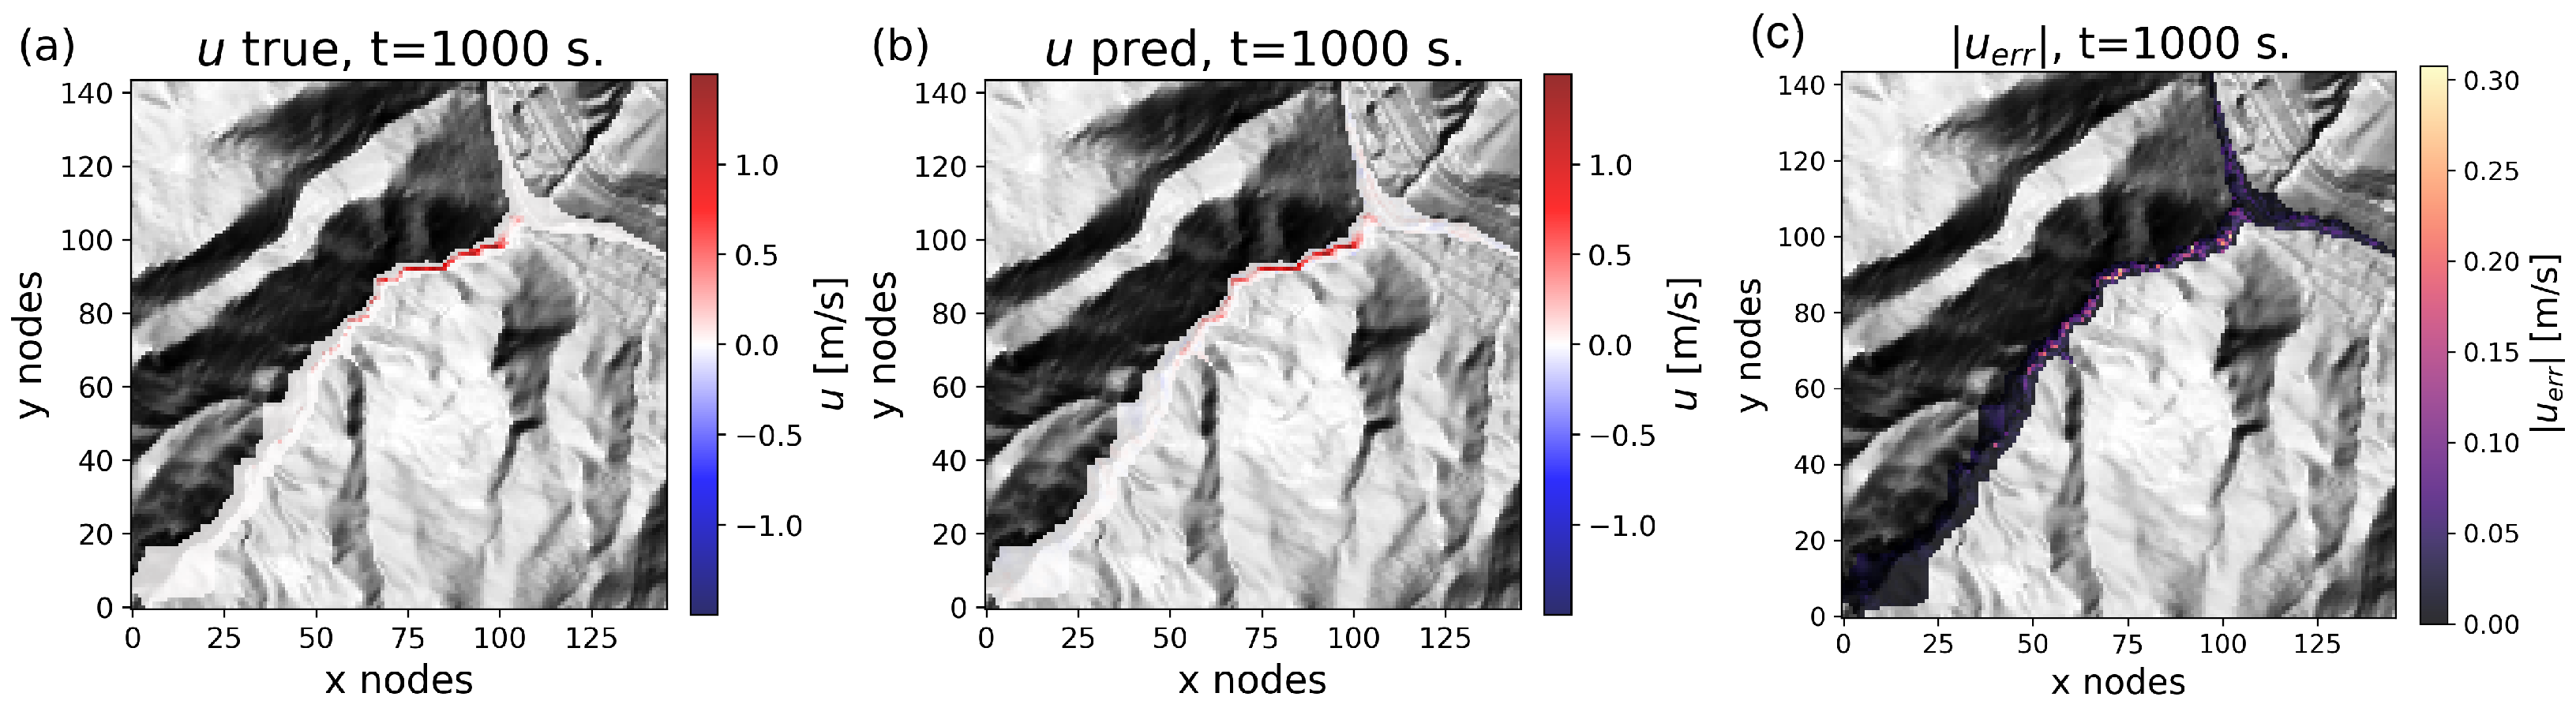
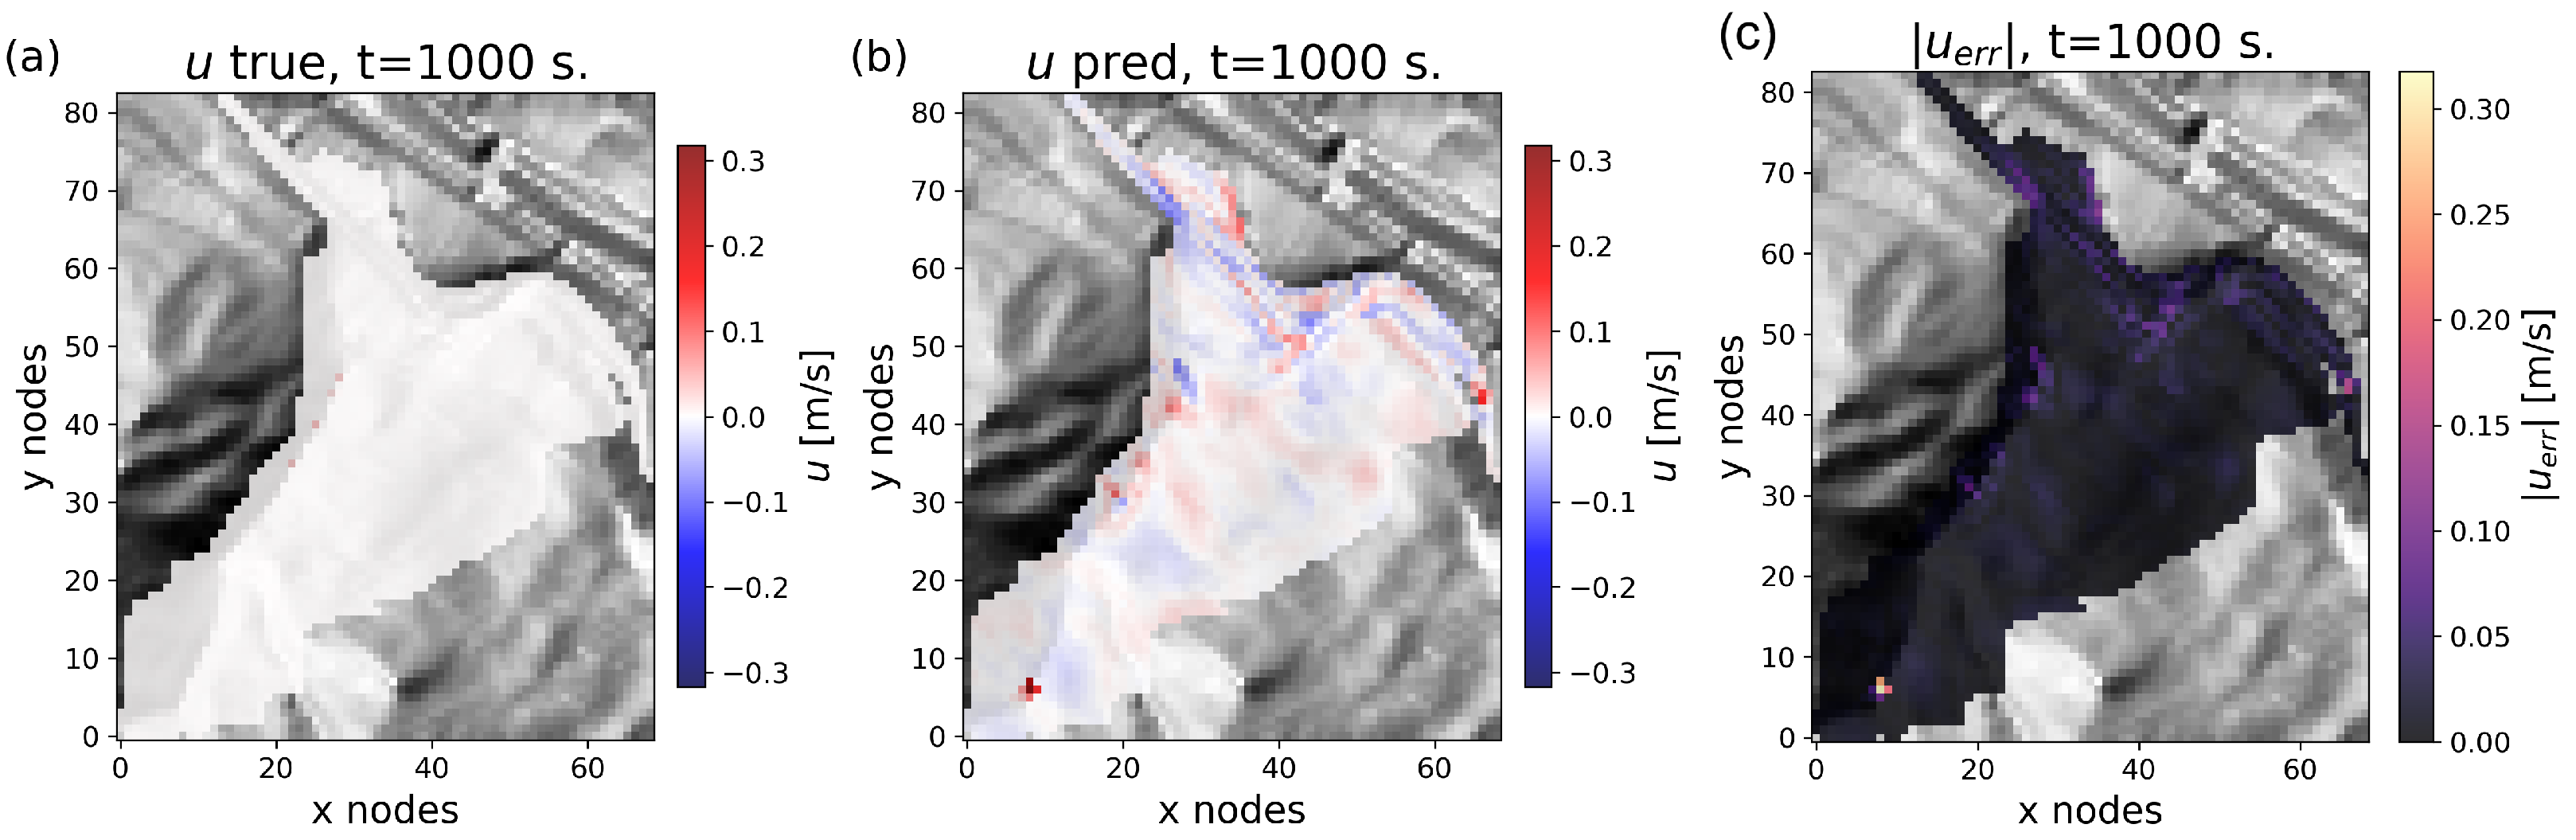
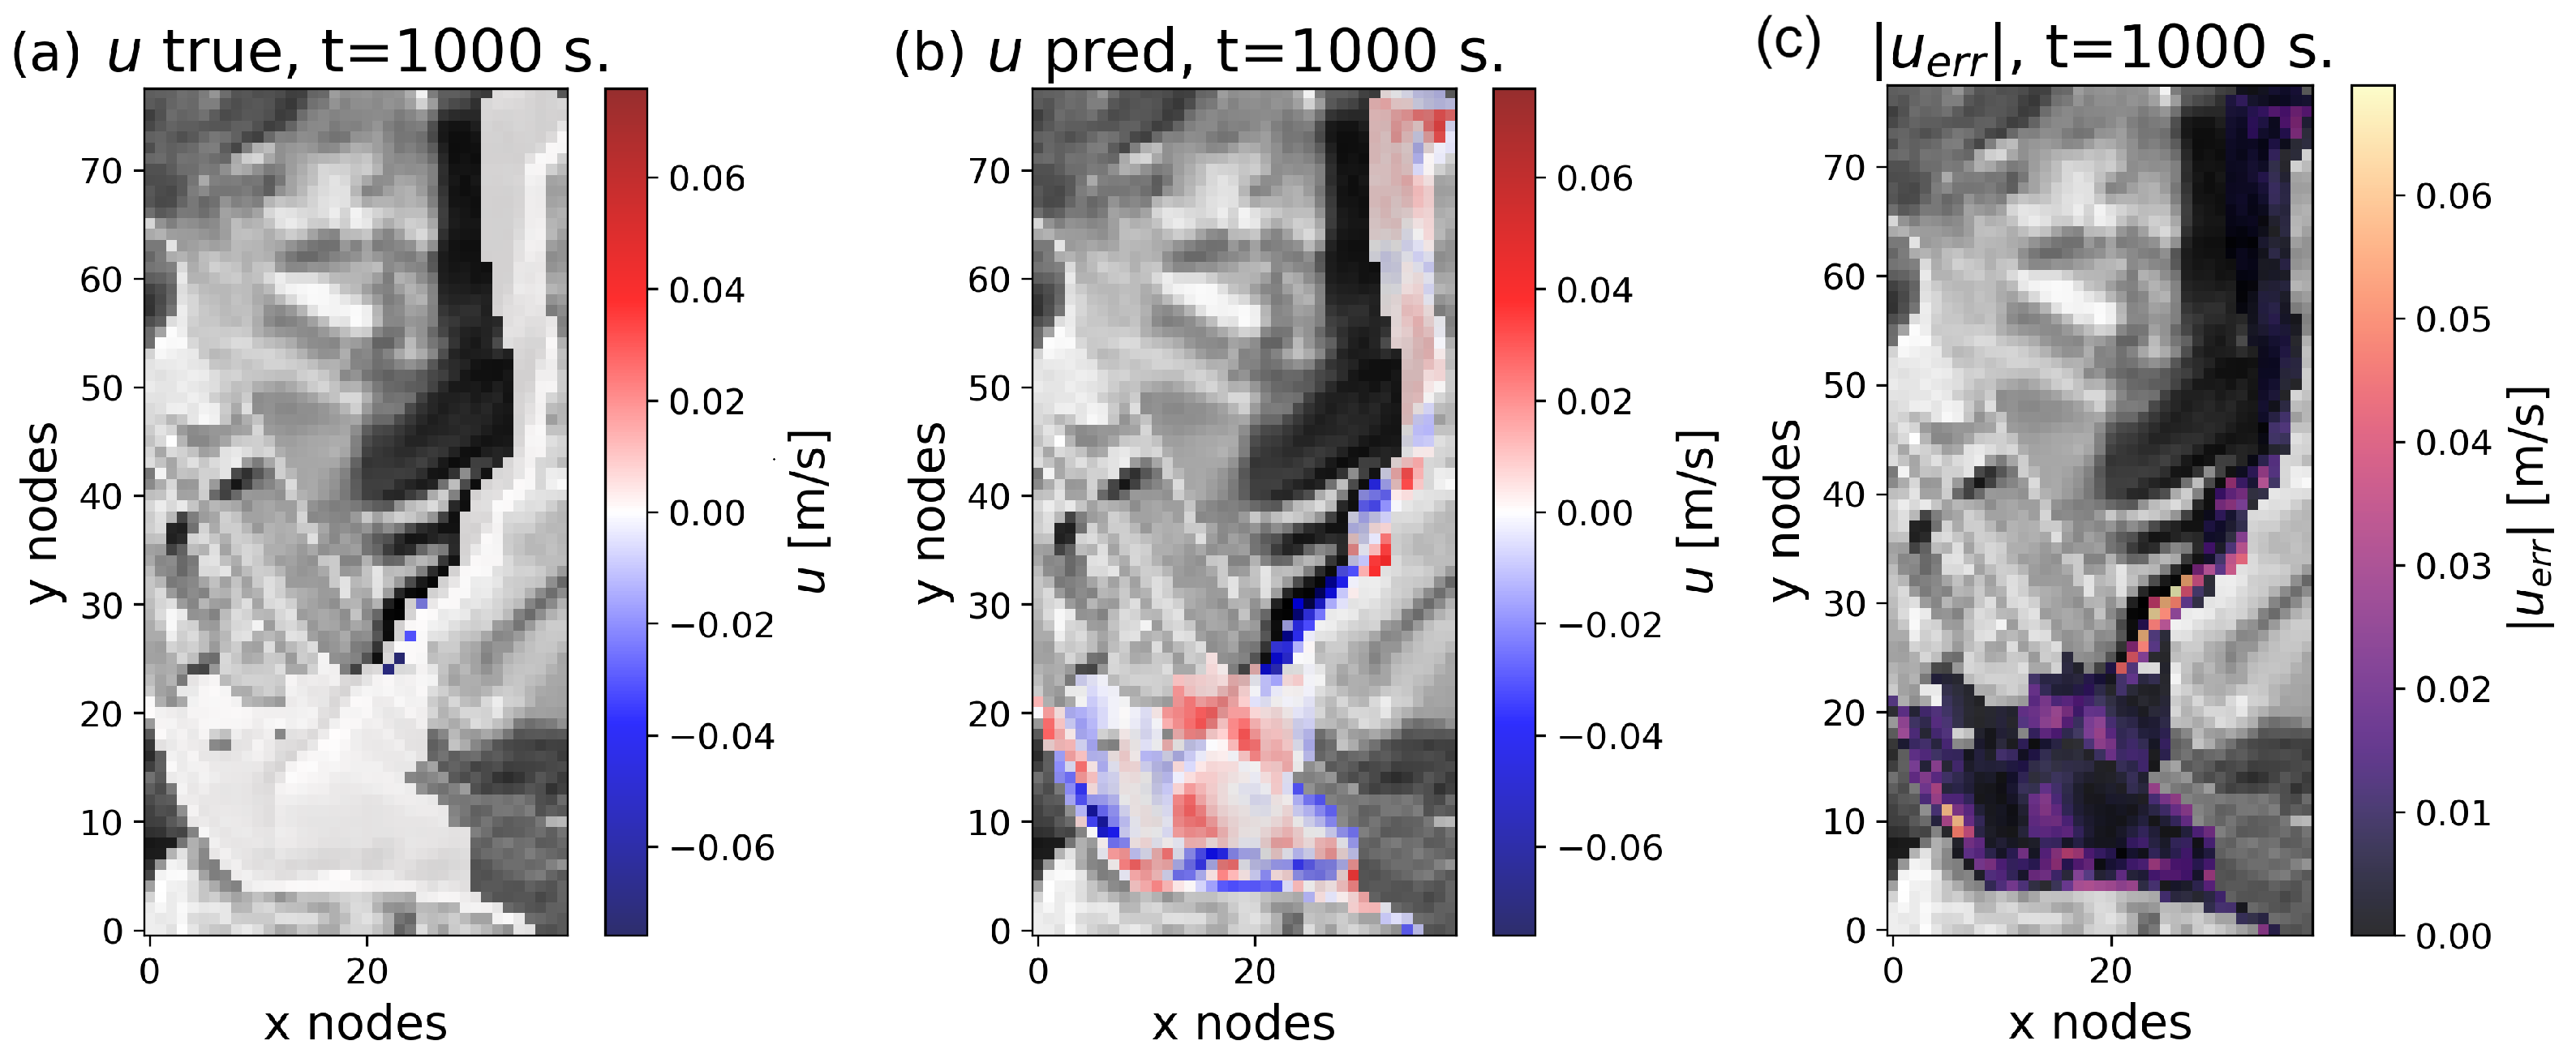
Overall, these results confirm that the surrogate remains robust across different flow configurations, although the velocity field is more sensitive than the depth field to localized dynamical variations and to fine-scale topographic control.
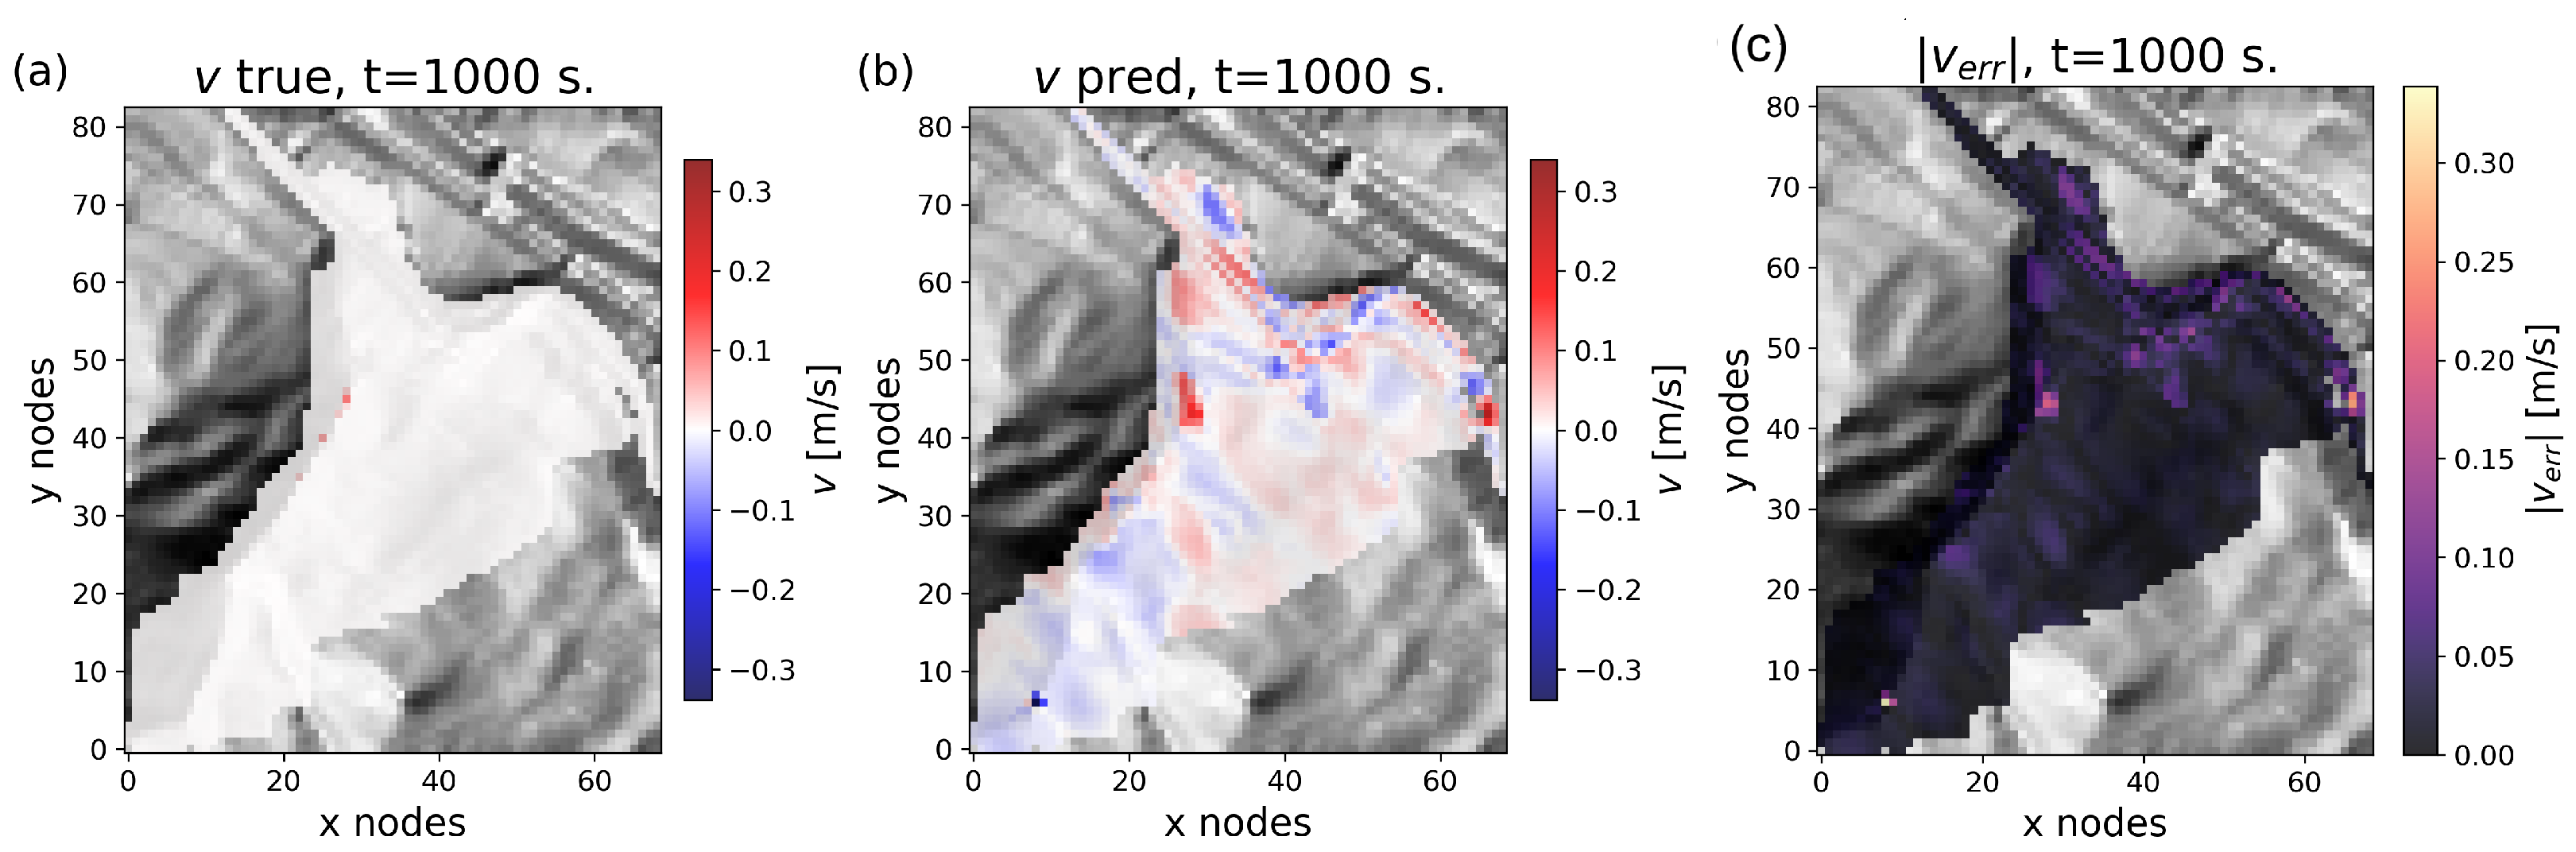
Figure 10,
Figure 11 and
Figure 12 compare the reference and predicted longitudinal velocity component
u at the final simulation time. In sample_000029, the predicted field reproduces the main spatial organization of the velocity pattern, and the discrepancies remain weak and localized. The associated absolute error map, shown in panel (c) of
Figure 10, confirms that the largest differences are concentrated near the active flow corridor and around localized peaks, while most of the deposited area exhibits limited error.
For sample_000079, the reconstruction of
u is more challenging. The predicted field still preserves the dominant channelized structure and the main zones of positive velocity, but localized departures become more visible along the flow path and near branching regions. The corresponding error map, shown in panel (c) of
Figure 11, indicates that the mismatch is concentrated along the active runout corridor, where sharp spatial gradients and small positional offsets amplify the pointwise error. This behaviour is consistent with the higher relative error and lower
reported in
Table 9.
For sample_000045, the reconstruction of
u is substantially more demanding. Although the predicted field still captures the main channelized corridor and the overall downslope organization of the motion, the discrepancies are more widespread and become clearly visible both along the curved runout path and across the broader depositional sector. The corresponding error map, shown in panel (c) of
Figure 12, indicates that the mismatch is no longer confined only to a few localized peaks, but extends over a larger fraction of the active domain. This behaviour is consistent with the much larger relative error and lower
reported in
Table 9, and confirms that the longitudinal velocity component represents one of the most demanding targets in this validation case.
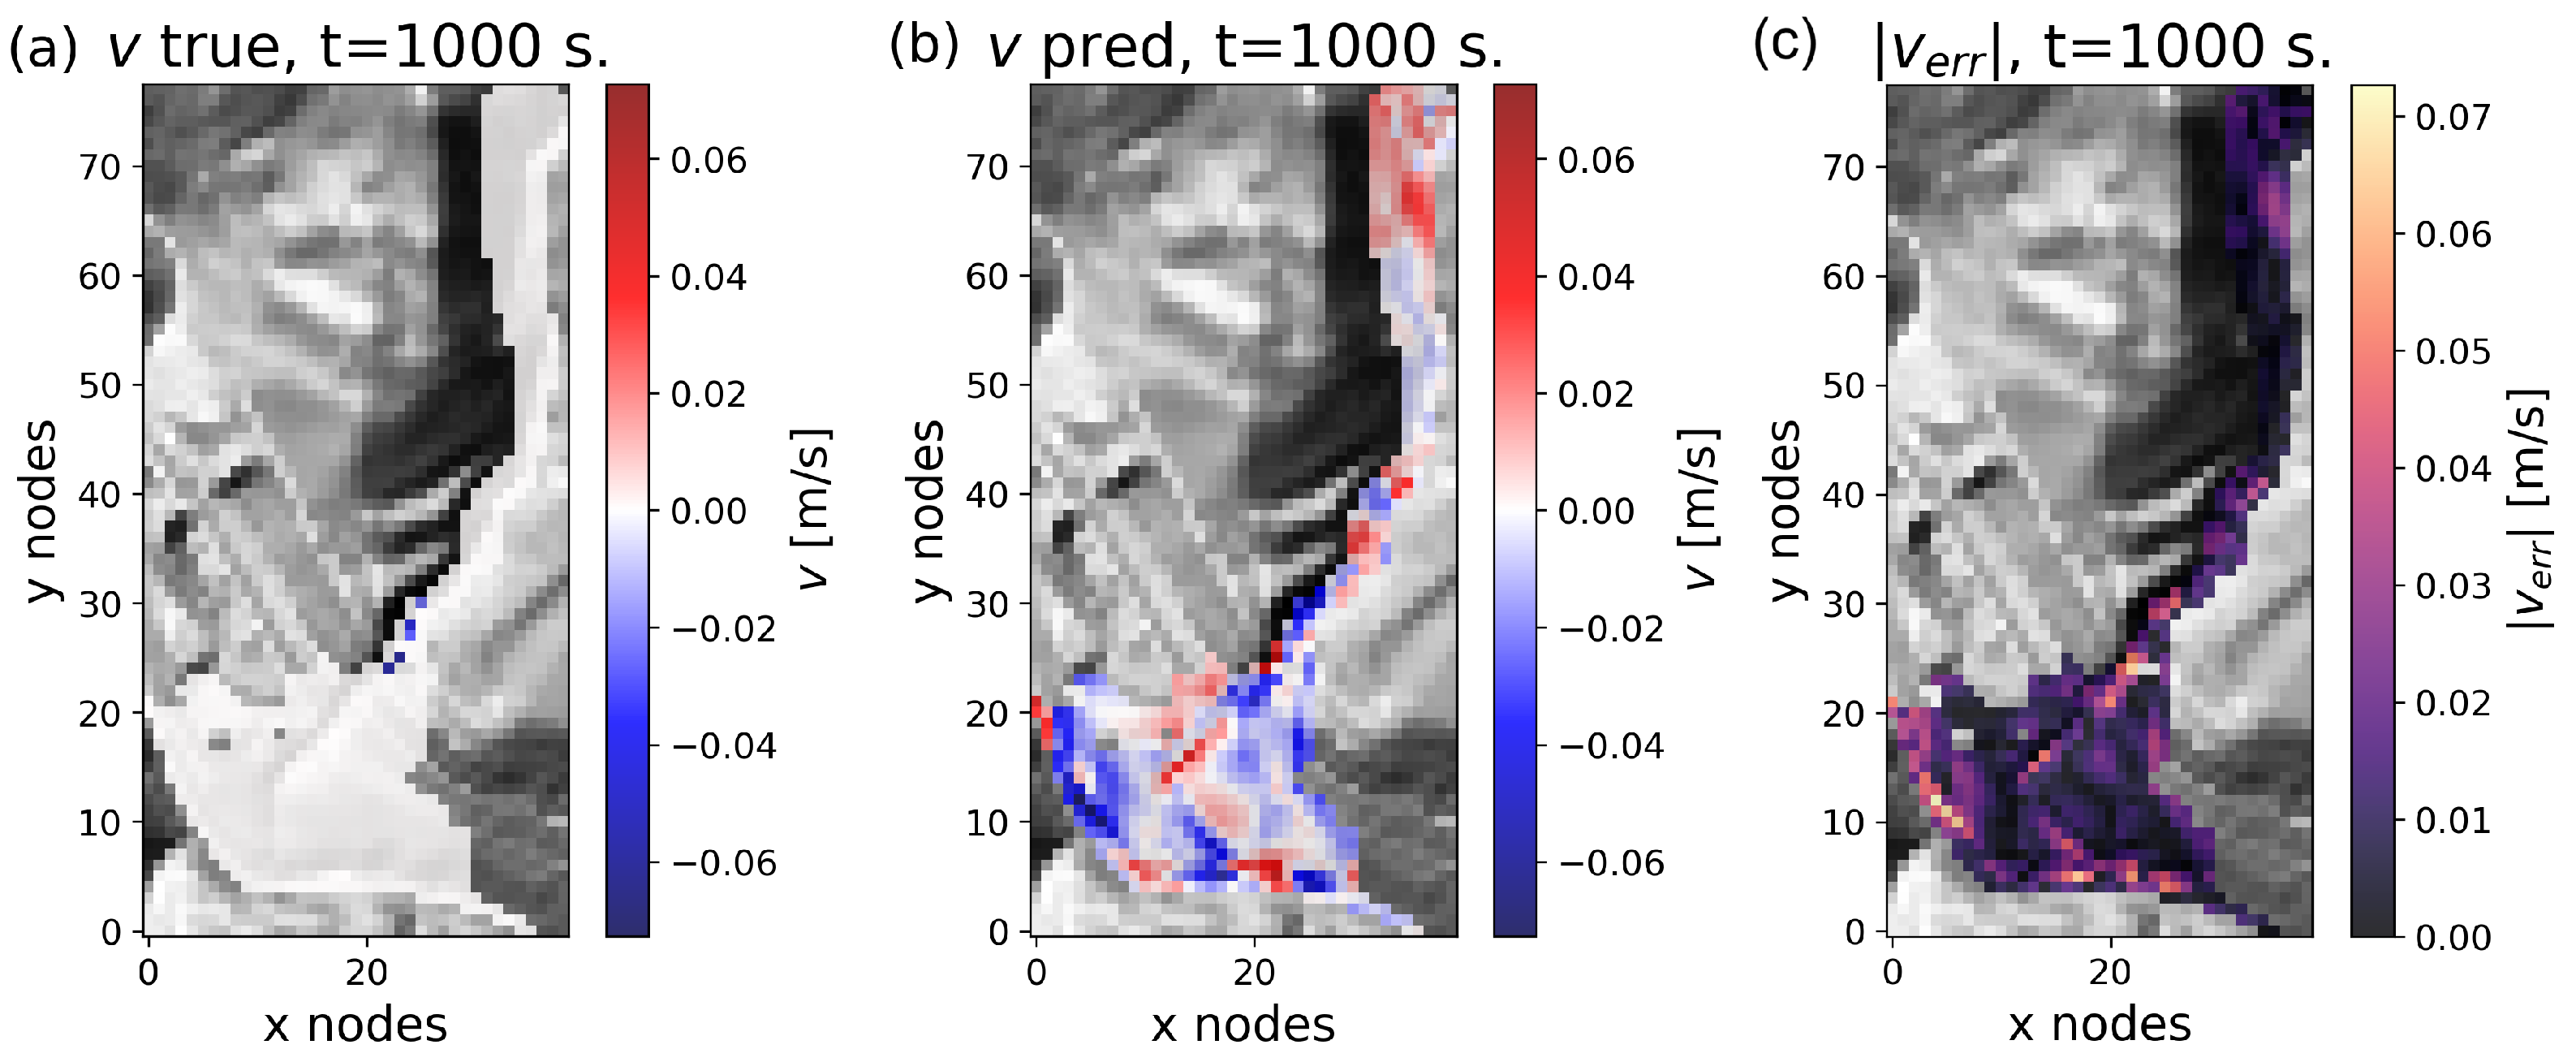
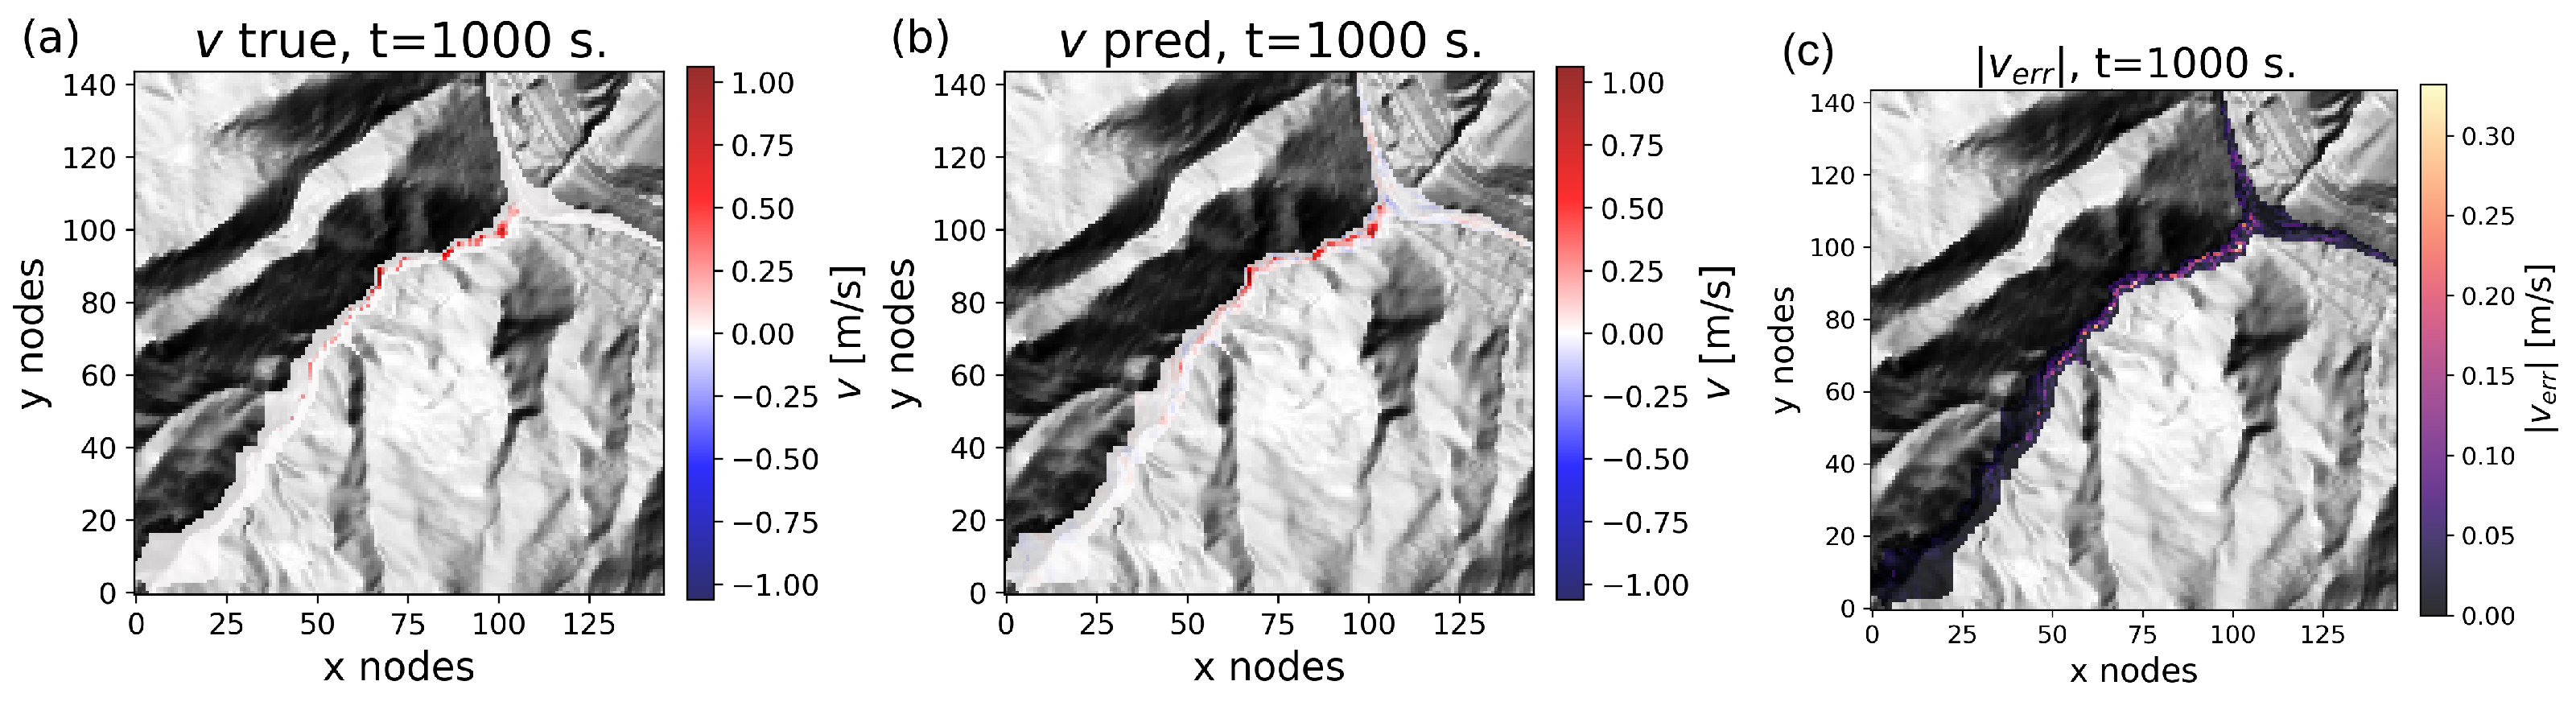
Figure 13,
Figure 14 and
Figure 15 report the same comparison for the transverse velocity component
v. In both validation samples, the surrogate is able to recover the main lateral velocity structure with satisfactory accuracy. For sample_000029, the predicted field remains close to the reference, and the error is concentrated in a few localized regions of stronger lateral motion. For sample_000079, the spatial structure of
v is also well captured, although moderate discrepancies appear near the channel junction and along the most active sectors of the flow. Even so, the absolute error remains spatially confined, in agreement with the still high coefficient of determination. For sample_000045, the reconstruction of
v is also more demanding than in the previous two cases, with visibly larger discrepancies over the depositional sector and along parts of the curved channelized path. However, the main lateral-flow organization is still reasonably captured, and the error remains more moderate than for the longitudinal component
u, in agreement with the lower relative error and higher
reported in
Table 9.
Taken together, the velocity maps indicate that the surrogate captures the dominant kinematic organization of the flow in the analyzed validation cases. The main discrepancies are localized in the dynamically active portions of the domain, especially where the flow is strongly channelized or where rapid spatial variations occur. At the same time, the inclusion of sample_000045 shows that these discrepancies can become substantially more pronounced in the most demanding configurations, particularly for the longitudinal velocity component u. Overall, the surrogate still reproduces the velocity field with satisfactory physical coherence, while retaining some limitations in the most challenging local dynamical regions.
It is also important to observe that, even in the most demanding validation case, the residual discrepancies in the velocity fields remain comparatively small in absolute magnitude. Although the spatial mismatch is more extended for sample_000045, particularly for the longitudinal component u, the corresponding error maps show that the residual velocities are generally limited. This indicates that the deterioration in the error metrics is not associated with large unphysical velocity departures, but rather with more diffuse local discrepancies in regions where the predicted motion remains of relatively small magnitude.
5. Discussion
The results of
Section 4 show that the FNO trained on synthetic 2D debris-flow simulations reproduces the spatio-temporal dynamics of the reference finite-volume solver with effective overall accuracy across the explored parameter range. The surrogate captures depositional patterns and the joint evolution of flow thickness and depth-averaged velocity over multiple release settings in the Morino–Rendinara area, demonstrating the application of the proposed general surrogate-modelling framework to a site-specific Morino–Rendinara model, extending operator learning from simplified 1D cases to a more realistic 2D terrain-controlled framework.
These results should nevertheless be interpreted within the adopted setting. Because the surrogate is trained on synthetic data generated by a validated numerical solver, it should be viewed as a site-specific surrogate of the underlying depth-averaged model rather than as a universal substitute for physics-based simulation. Validation shows stable and physically coherent predictions on within-distribution validation samples, with the main discrepancies concentrated near wet–dry fronts, narrow channelized sectors, and local depositional peaks. Velocity remains more difficult to reconstruct than thickness, but the model preserves the dominant kinematic structure and captures the coupling between flow variables and terrain morphology.
A central methodological outcome is the importance of the training objective. The masked and weighted loss, designed to exclude padded cells, emphasize active-flow regions, and assign greater importance to velocity channels, proves essential for balancing depositional accuracy and kinematic fidelity. More broadly, this suggests that loss-function design should be treated as a key component of the modelling strategy in physically structured multi-output problems.
From an operational perspective, the main strength of the surrogate lies in efficiency. Once trained, the FNO replaces repeated numerical time integration with a single forward pass, making the prediction of full spatio-temporal fields much lighter than repeated execution of the finite-volume solver. This substantially facilitates the exploration of multiple combinations of release volume, density, release geometry, and friction zoning, while leaving the numerical solver essential for data generation and surrogate validation.
This efficiency has direct implications for probabilistic and large-ensemble hazard analysis. By reducing the marginal cost of each simulation, the surrogate makes Monte Carlo sampling, sensitivity analysis, uncertainty propagation, and rapid scenario screening much more feasible. Since it predicts not only final deposits but also the full evolution of depth and velocity, it also supports uncertainty-aware analyses of runout timing, arrival times, transient peak velocities, and time-dependent hazard intensity. For the representative case analyzed here, the surrogate reduced the time from approximately 47 s to s, corresponding to a speed-up factor of about . This factor should be interpreted as a case-specific speed-up relative to the first-order in-house finite-volume configuration used for dataset generation. Its absolute value may vary with the numerical order of the solver, implementation details, hardware, and degree of optimization, and should therefore not be interpreted as a universal benchmark against all physics-based solvers.
The results also highlight the feasibility of site-specific neural surrogates. In the present case, the dataset is tailored to the Morino–Rendinara area and represents plausible variations within the same basin-scale context. For many engineering applications, this is a practical advantage, as hazard assessment is often performed at the scale of a single catchment or valley sector. In this sense, the framework supports a modular hazard-modelling strategy in which physics-based solvers, neural surrogates, and probabilistic post-processing act as complementary components.
From a territorial-risk perspective, this capability is particularly relevant in catchments such as Morino–Rendinara, where scenarios similar to past hydrogeological events may affect sectors located close to exposed elements, including buildings and local infrastructure. In this sense, a fast surrogate model may support not only hazard simulation, but also susceptibility-oriented screening of potentially affected areas under multiple plausible release scenarios.
Despite the promising predictive skill and practical potential of the framework, several limitations remain. Future developments should address improvements in the physical and numerical model used to generate synthetic data, including more advanced spatio-temporal representations of bulk density, erosion–entrainment, segregation, adaptive meshing, constitutive behaviour, and time-dependent forcing. Dataset expansion will also be important, through additional release locations, broader parameter sampling, closer calibration against field observations, and the integration of real-world observational data, such as InSAR measurements or UAV-derived DEMs, for validation, calibration, and potential data assimilation, both to improve robustness within the basin and to extend the workflow to multiple catchments.
A further line of development concerns the machine-learning architecture. Although the 3D FNO proves effective for mapping spatio-temporal fields on structured raster grids and capturing non-local interactions, it may not be uniquely optimal for all debris-flow modelling settings. Graph Neural Networks (GNNs), for example, may be particularly suitable for irregular, unstructured, or adaptive meshes, where local resolution can be increased near wet–dry fronts, channelized paths, sharp topographic transitions, and depositional margins [
47,
48,
49]. Deep Operator Networks (DeepONets) and transformer-based operator models represent promising alternatives for learning parametric solution operators and long-range dependencies, although their advantages may depend on data availability, geometry, and computational cost [
33,
50]. In parallel, physics-informed neural networks, physics-informed neural operators, and recent solver-free or equation-driven approaches may reduce the dependence on large precomputed solver datasets by incorporating governing equations, residual constraints, derivative information, or compositional physical structure into the learning process [
51,
52,
53,
54,
55,
56]. Systematic benchmarking against these alternatives, together with deeper analysis of FNO hyperparameters, may help reduce the remaining errors and clarify the trade-offs among accuracy, efficiency, robustness, data requirements, physical consistency, and interpretability.
6. Conclusions
This study investigated the use of an FNO within a general surrogate-modelling framework for 2D debris-flow simulations, applied here to the Morino–Rendinara area. The proposed framework combines a validated finite-volume shallow-flow solver with operator learning in order to approximate the full spatio-temporal evolution of debris-flow thickness and depth-averaged velocity over real topography. In this way, the trained surrogate is designed as a solver-consistent, site-specific surrogate of the numerical model, trained on synthetic scenarios generated within a site-specific geomorphological and rheological setting.
The results show that the trained FNO is able to reproduce the reference numerical solutions with good overall accuracy on within-distribution validation samples. In particular, the Morino–Rendinara surrogate captures the main runout pathways, depositional patterns, and the dominant kinematic structure of the flow, while maintaining limited relative errors for both flow thickness and the two horizontal velocity components. The validation analysis also shows that most discrepancies remain localized in dynamically sensitive regions, such as wet–dry fronts, narrow channelized sectors, and areas with stronger local topographic control, which is consistent with the intrinsic difficulty of approximating sharp space–time transitions in debris-flow propagation.
A relevant methodological contribution of the study lies in the design of the training objective. The use of a masked and weighted loss function made it possible to focus the optimization on the valid physical support of each sample and to assign greater importance to active-flow regions and to the velocity channels. This choice proved important for obtaining a balanced reconstruction of both depositional and kinematic variables, showing that objective-function design is not merely a technical detail, but a central component in the training of neural surrogates for multi-output geophysical flow problems.
From an applied perspective, the proposed surrogate offers a substantial practical advantage with respect to repeated numerical simulation. Once trained, the FNO can approximate the full spatio-temporal response of the solver at a much lower computational cost than explicit finite-volume integration. This makes the framework especially attractive for applications requiring repeated scenario evaluation, such as uncertainty propagation, Monte Carlo analyses, sensitivity studies, and rapid hazard-oriented screening over multiple plausible release conditions. In site-specific contexts, this may also support the assessment of territorial susceptibility to hydrogeological scenarios similar to past events, particularly where potential debris-flow runout may interact with nearby buildings, roads, and other exposed elements.
The study also supports the broader idea of site-specific operator-learning surrogates for debris-flow hazard analysis. Rather than aiming at a universal model applicable to arbitrary terrains, which would likely be prohibitive in terms of data requirements, statistical robustness, and computational cost, the present work shows that a basin-oriented surrogate trained on synthetic scenarios generated with a validated numerical solver and tailored to a given geomorphological context can achieve good predictive skill while remaining computationally efficient. In this sense, the methodology provides a practical pathway toward local site-specific surrogates for debris-flow simulation, with potential integration into probabilistic and decision-support workflows.
At the same time, the current framework has clear limitations. The surrogate learns the behaviour of the reference solver rather than the physical system directly, and its validity is therefore bounded by the assumptions of the depth-averaged model, the numerical formulation, and the representativeness of the synthetic dataset. In addition, the explored parameter space remains intentionally compact, and the present results should not be interpreted as evidence of reliable extrapolation beyond the release settings, parameter ranges, and terrain configurations included in training.
Future work will focus on extending the physical and numerical complexity of the synthetic simulations, enlarging the dataset across additional release scenarios and geomorphological contexts, and benchmarking the present FNO against alternative neural architectures. Particular attention will be devoted to richer rheological and erosion formulations, broader site-specific calibration, and tighter integration with probabilistic hazard-modelling strategies. These developments are expected to further strengthen the role of operator learning as a practical tool for fast, terrain-aware, and uncertainty-conscious debris-flow analysis in data-scarce mountain environments.