Article

Research on IMU Calibration Model Based on Polar Decomposition

School of Geomatics, Liaoning Technical University, Fuxin 123000, China
*
Author to whom correspondence should be addressed.
Micromachines 2023, 14(3), 697; https://doi.org/10.3390/mi14030697
Submission received: 12 February 2023 / Revised: 6 March 2023 / Accepted: 18 March 2023 / Published: 21 March 2023

Abstract

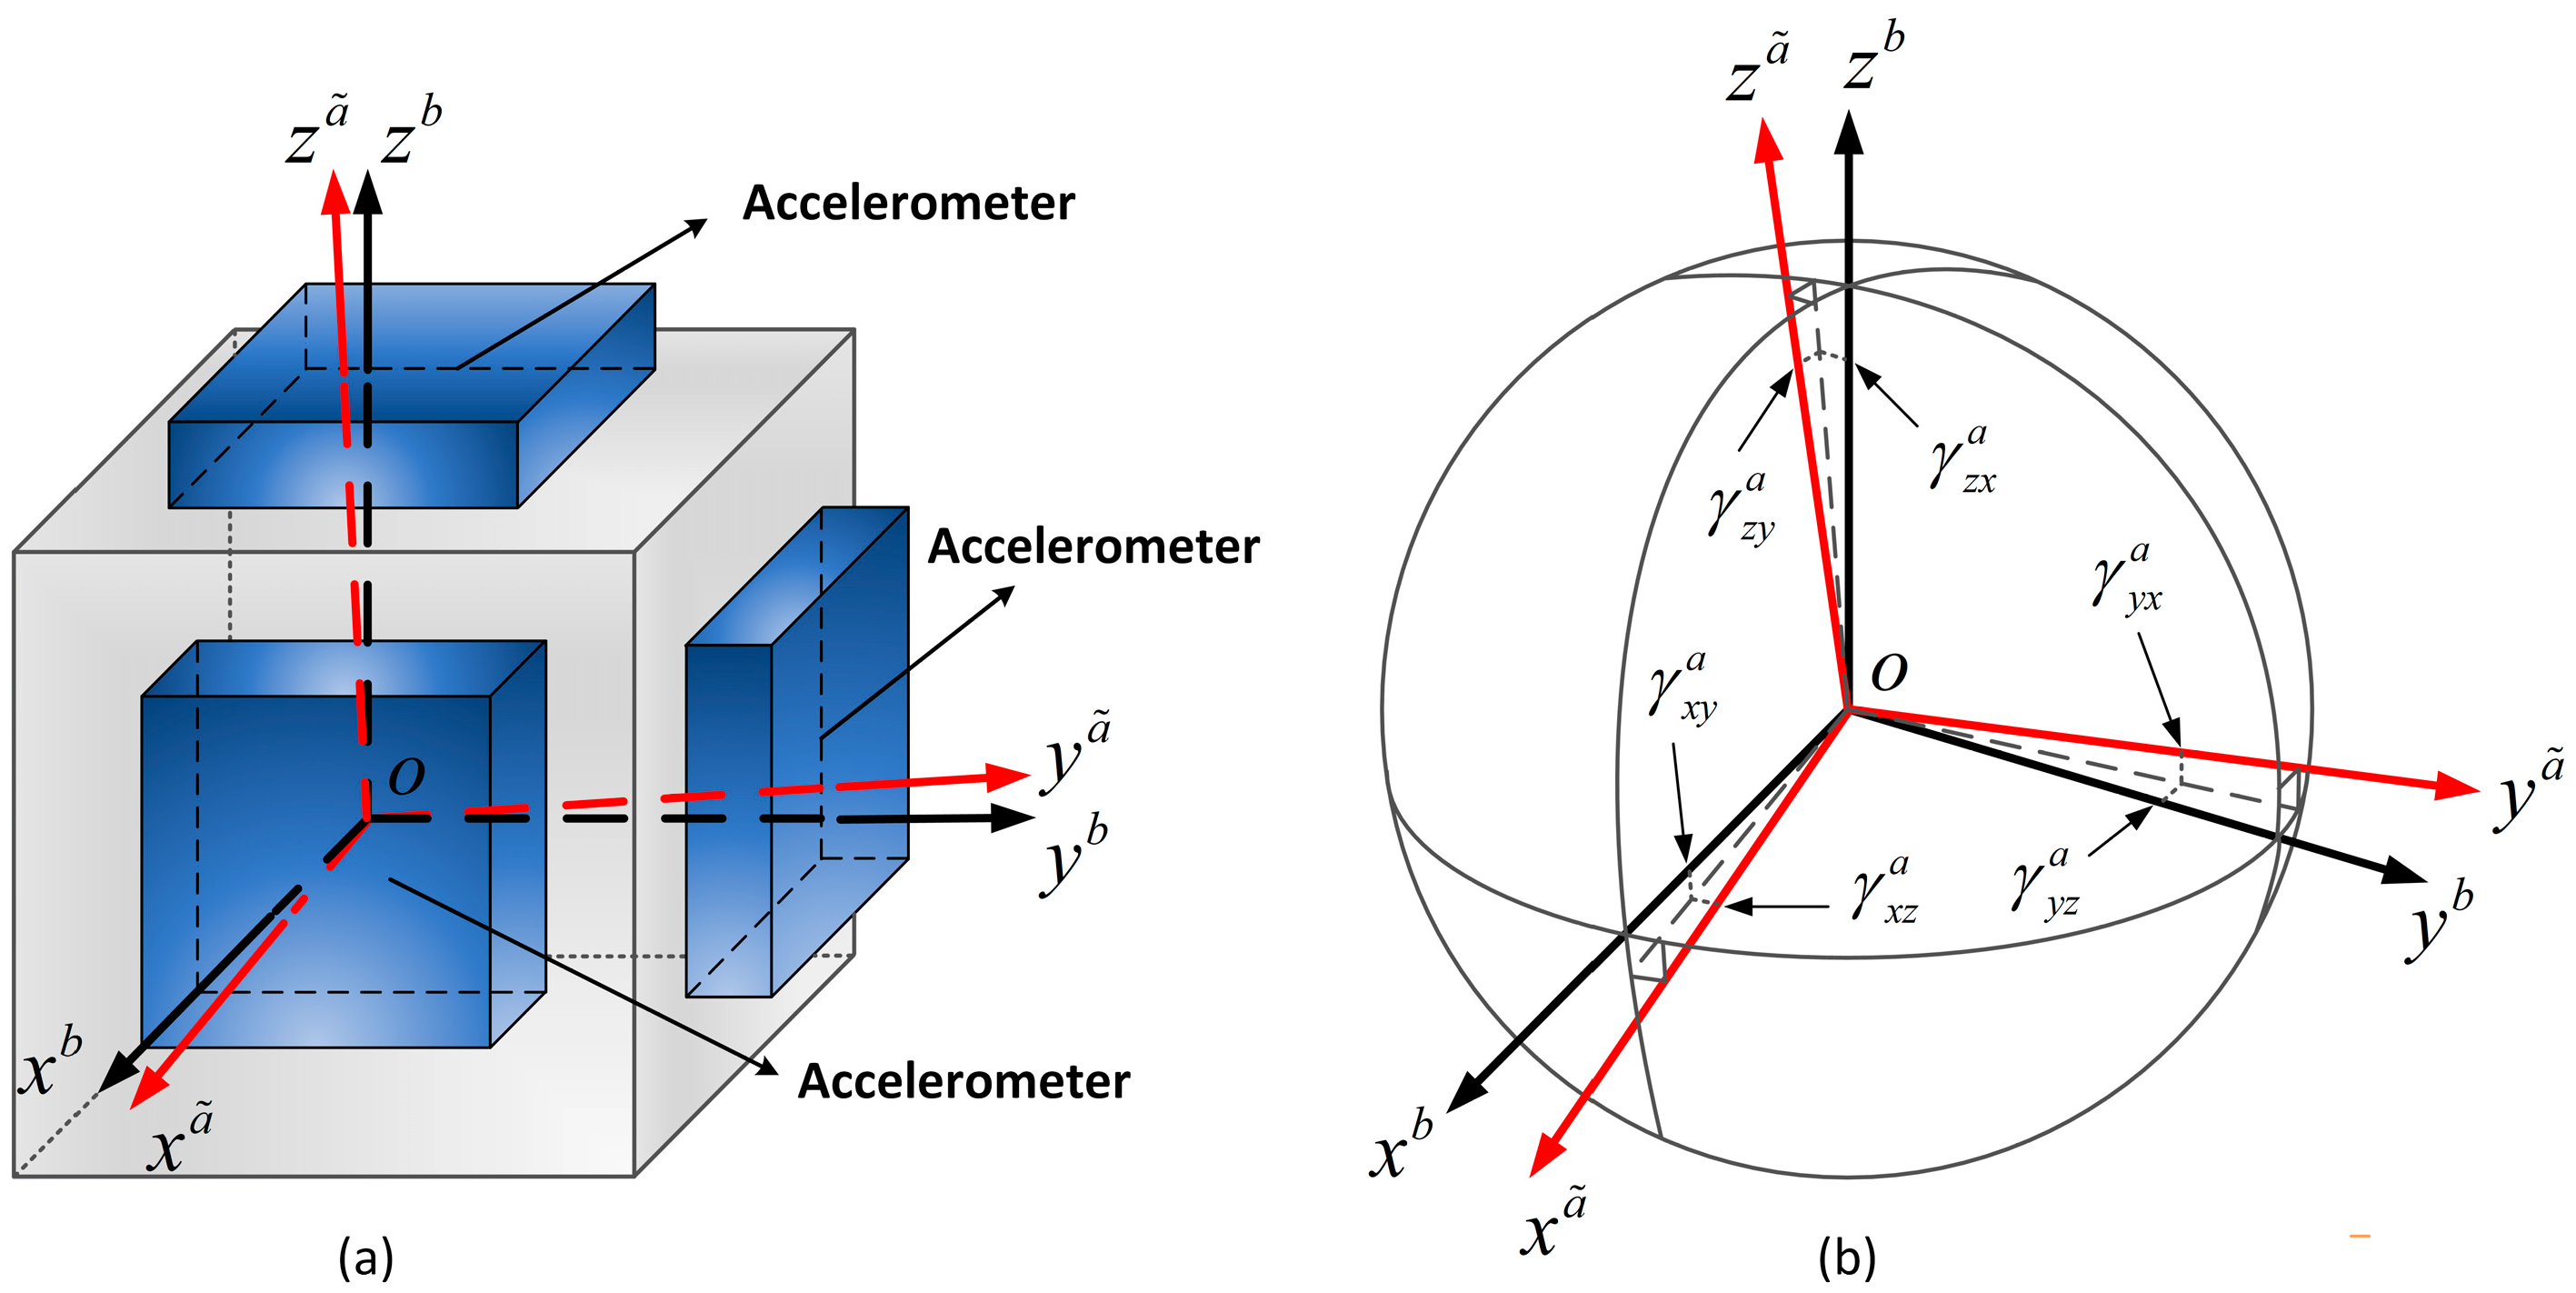
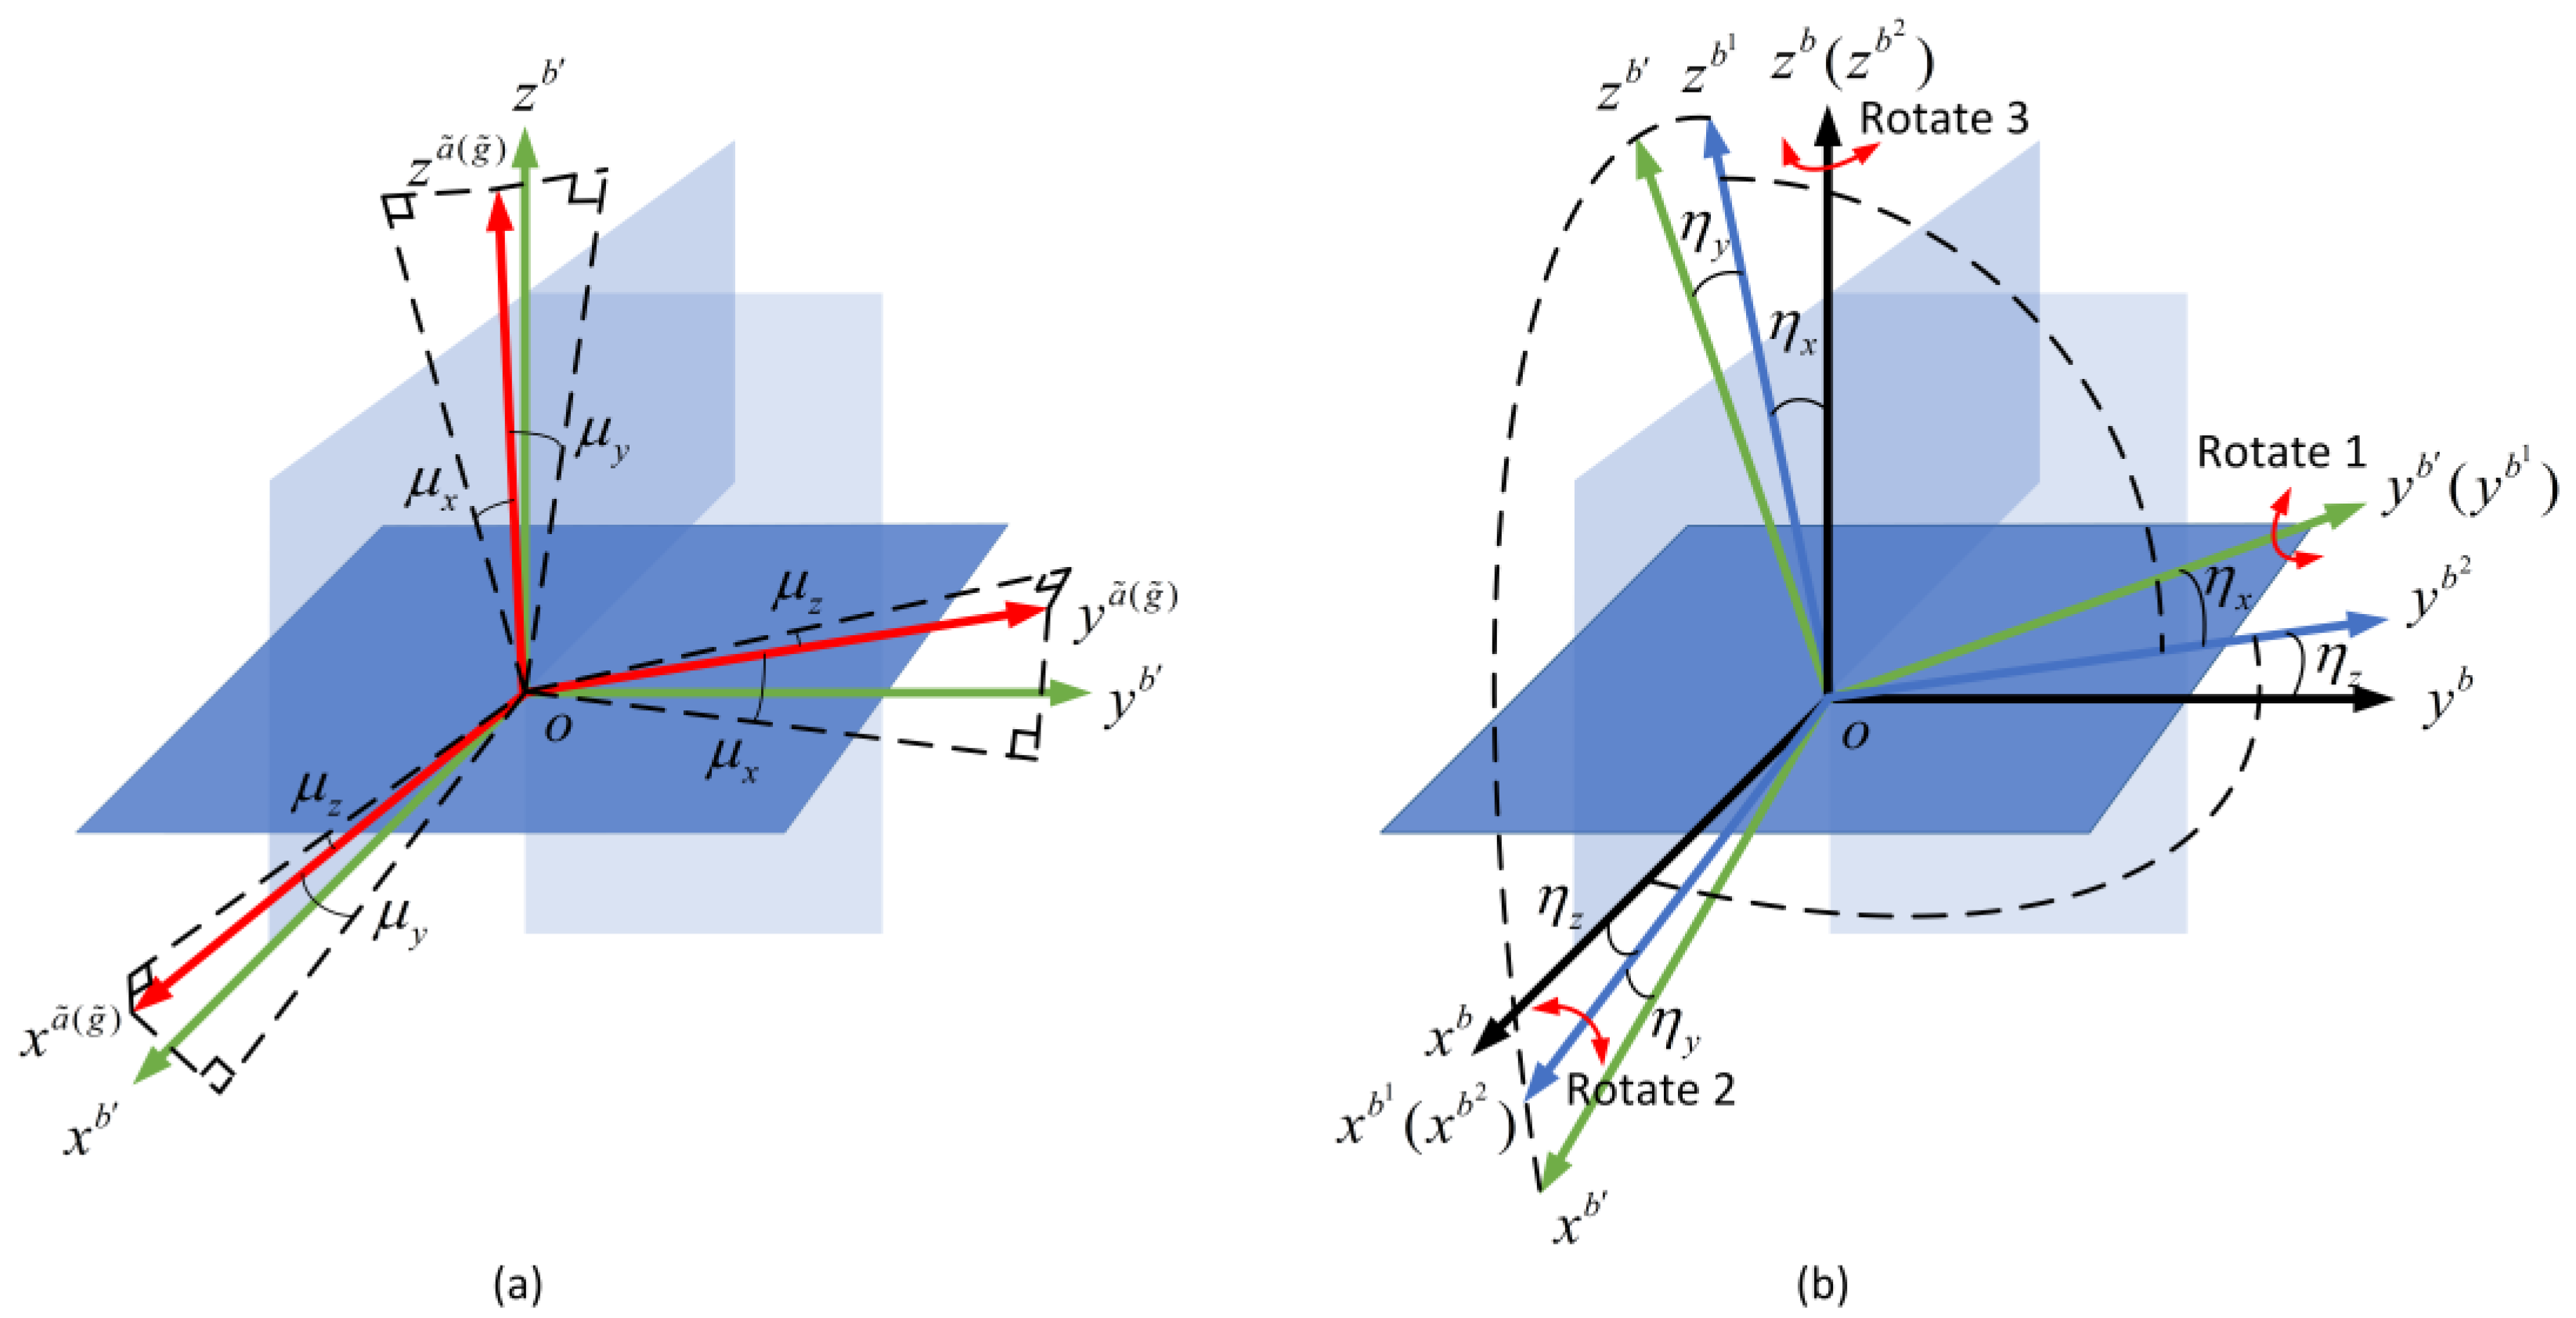
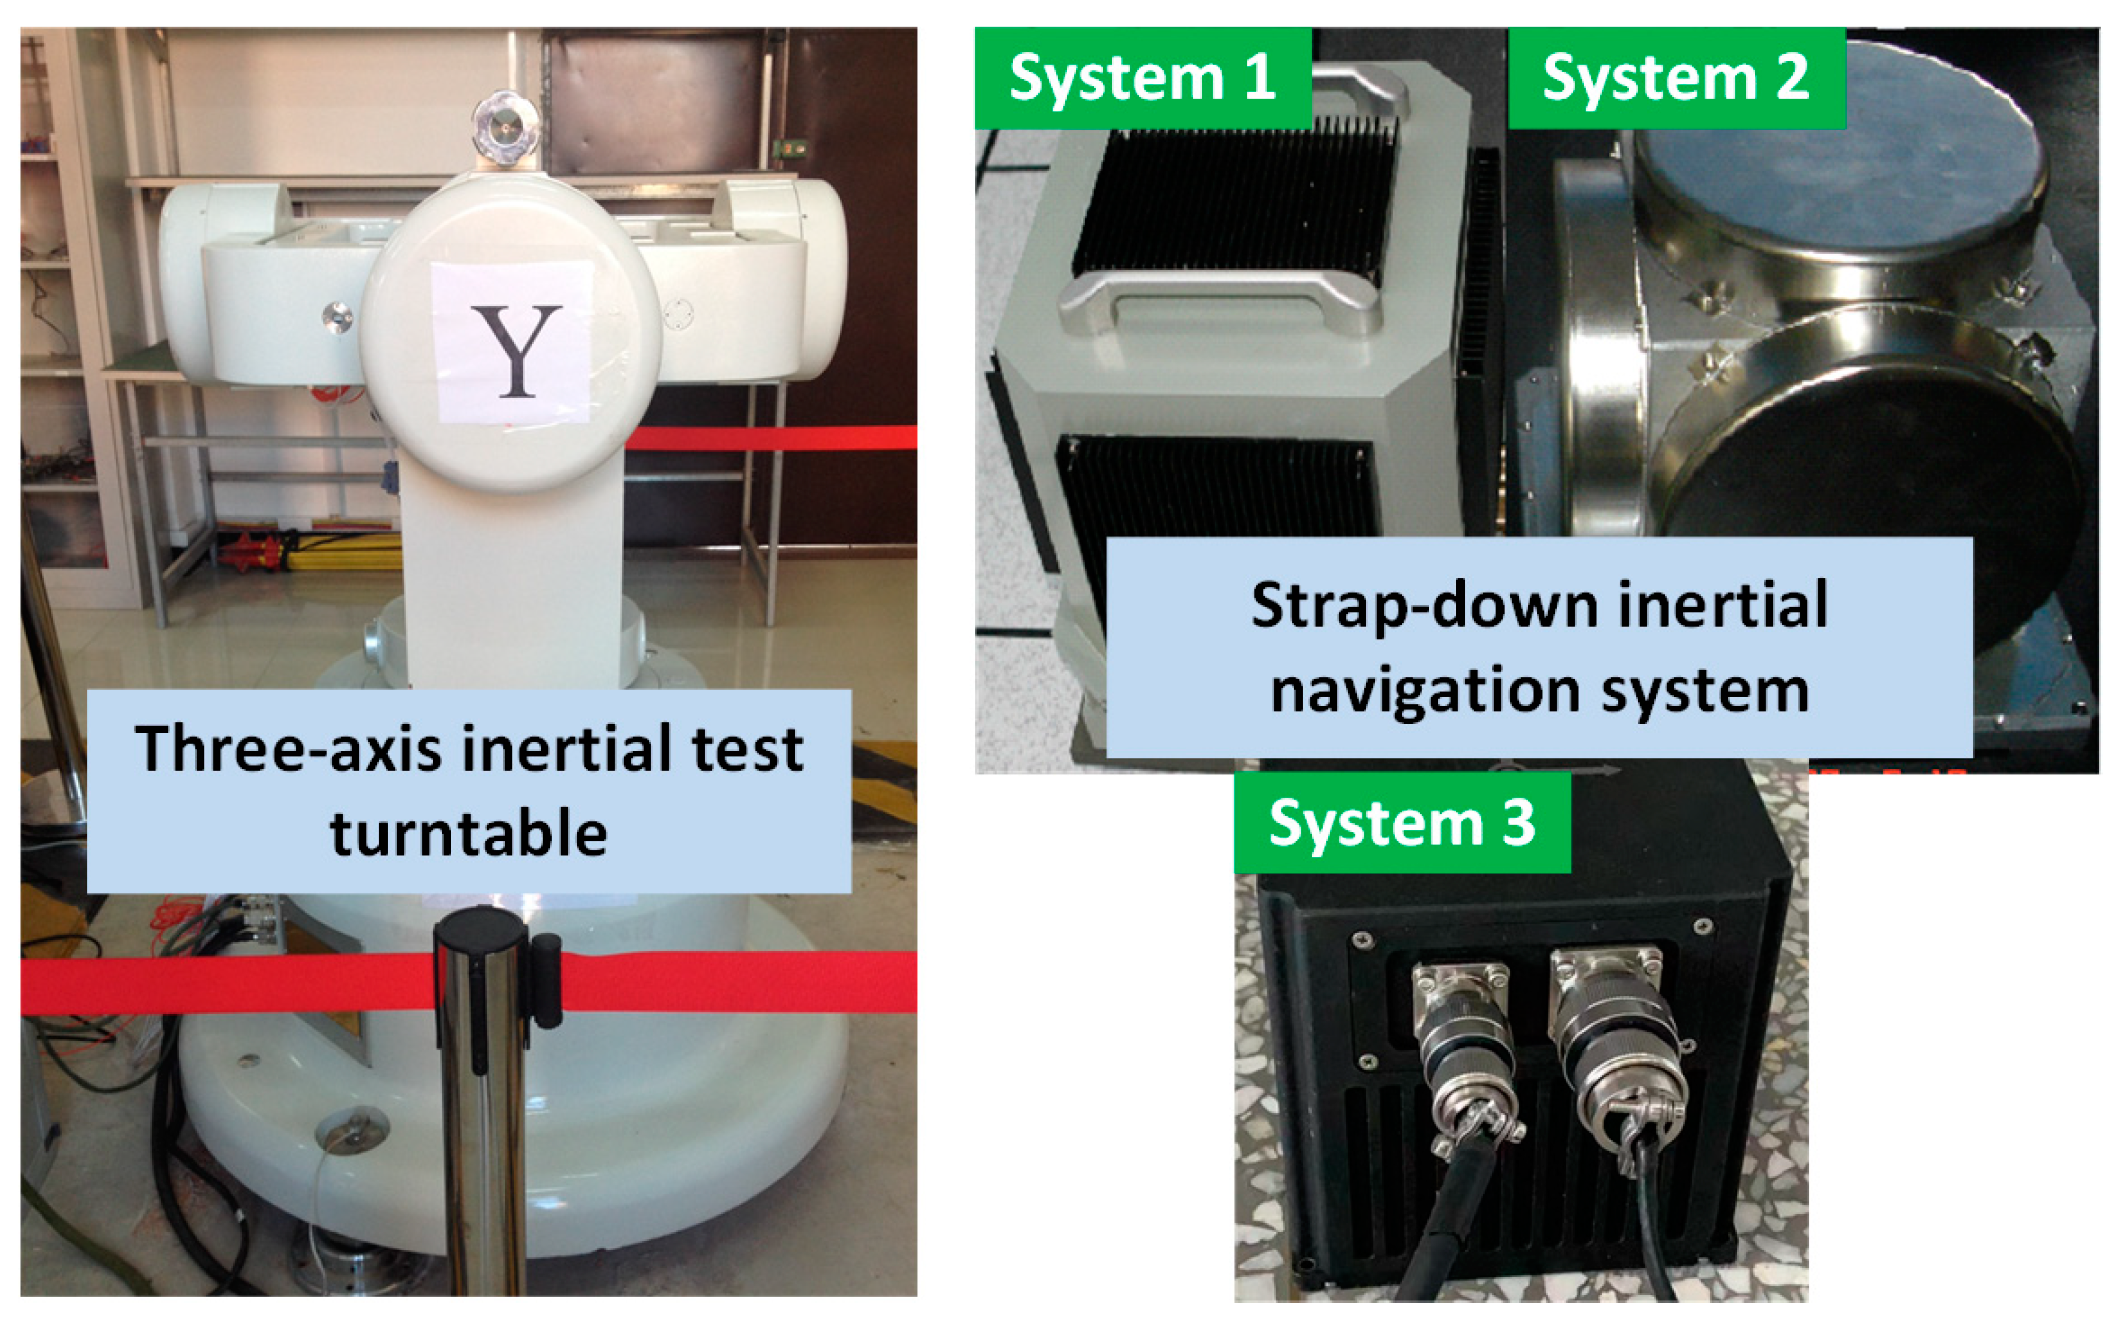
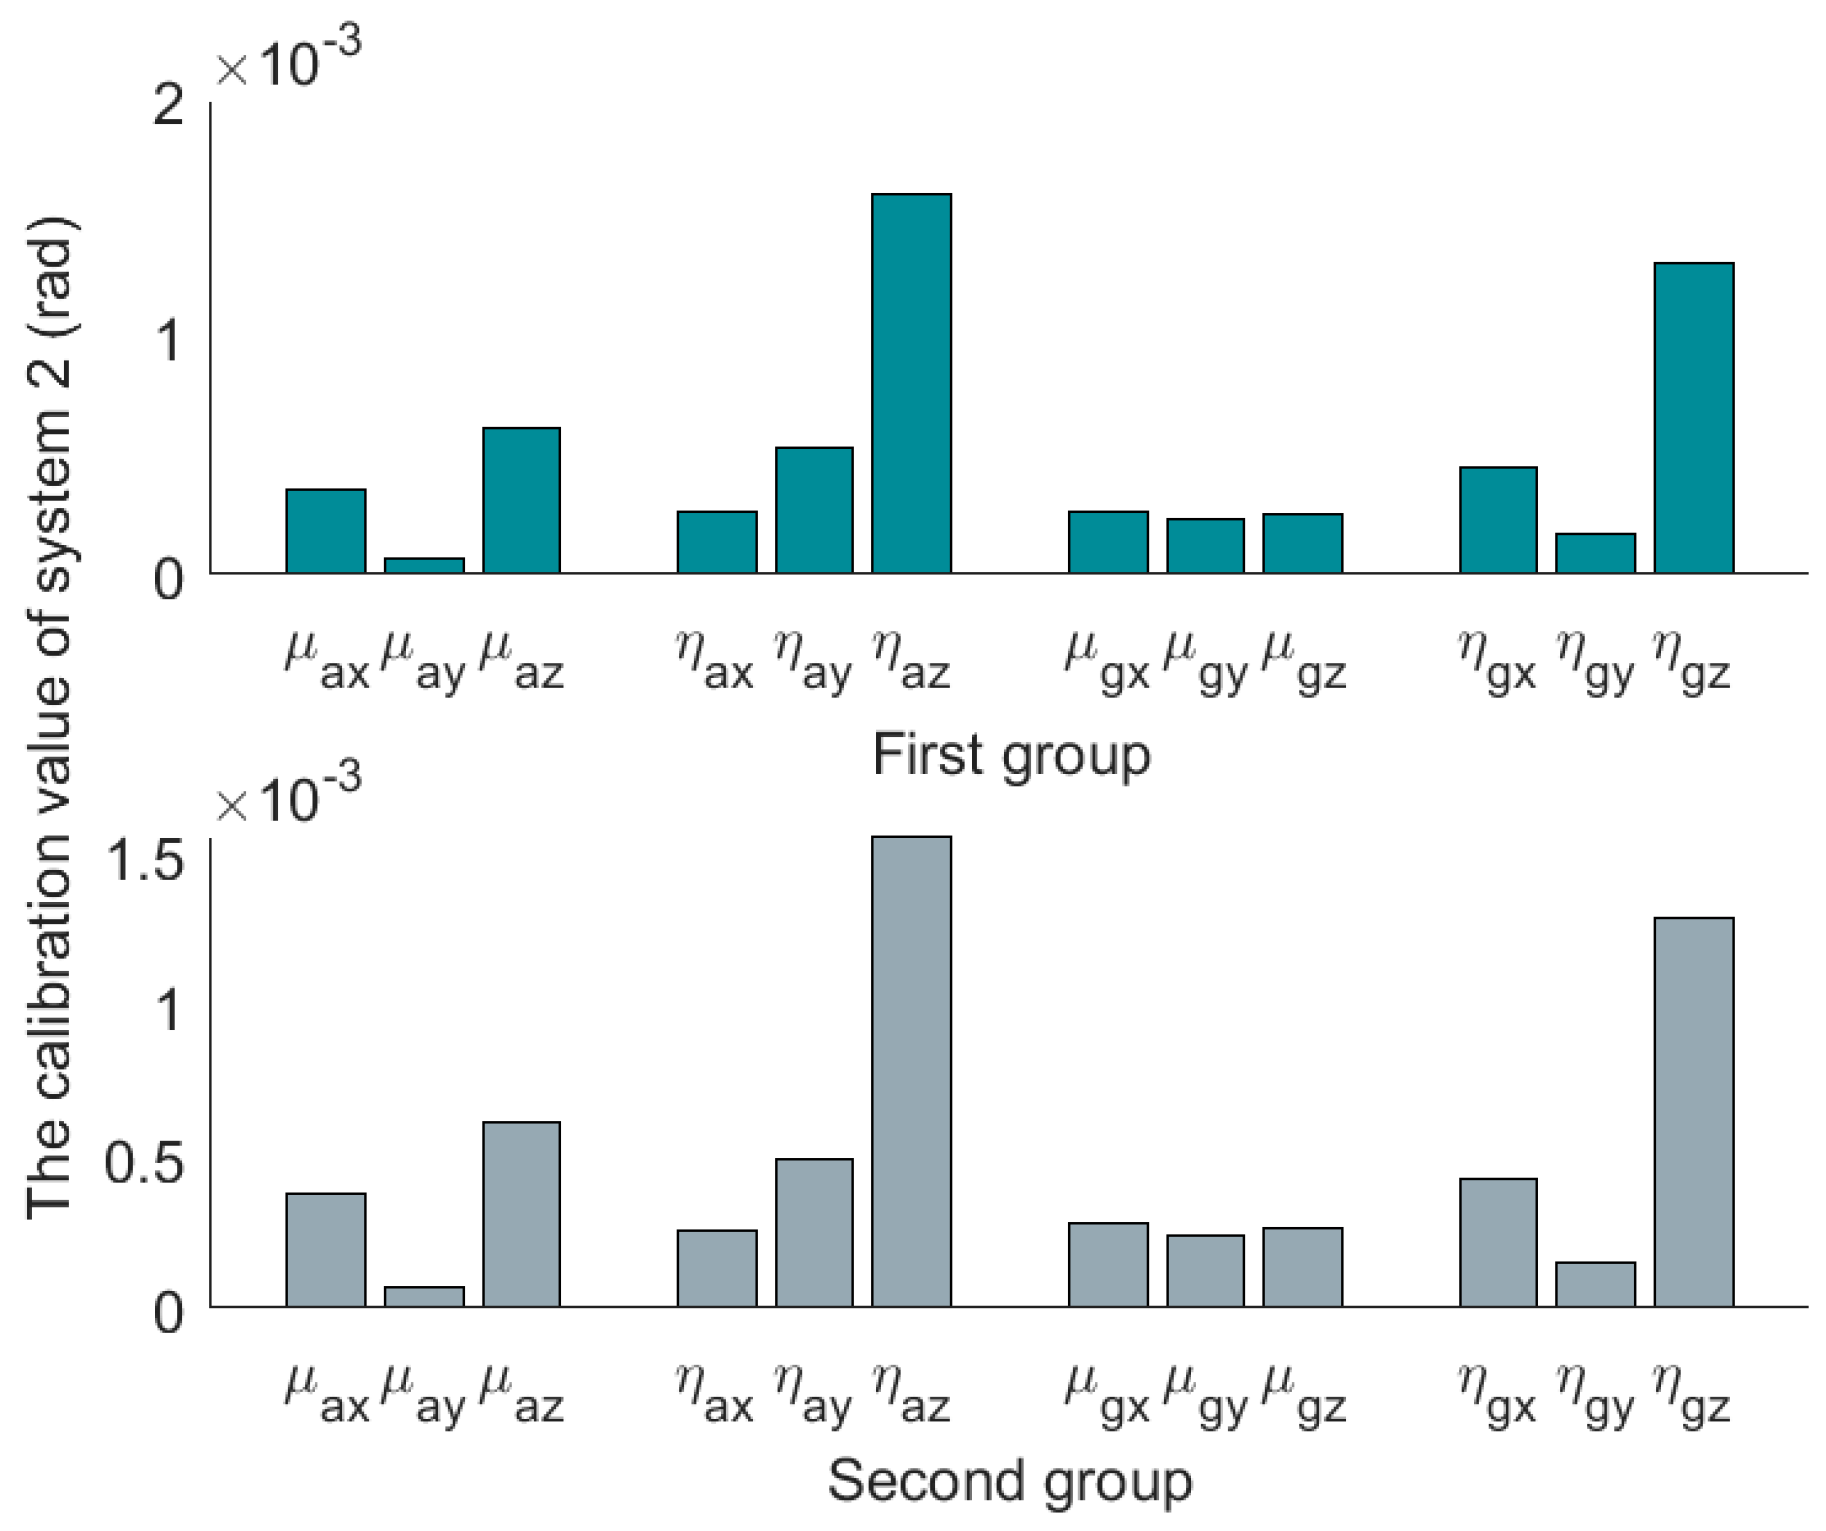
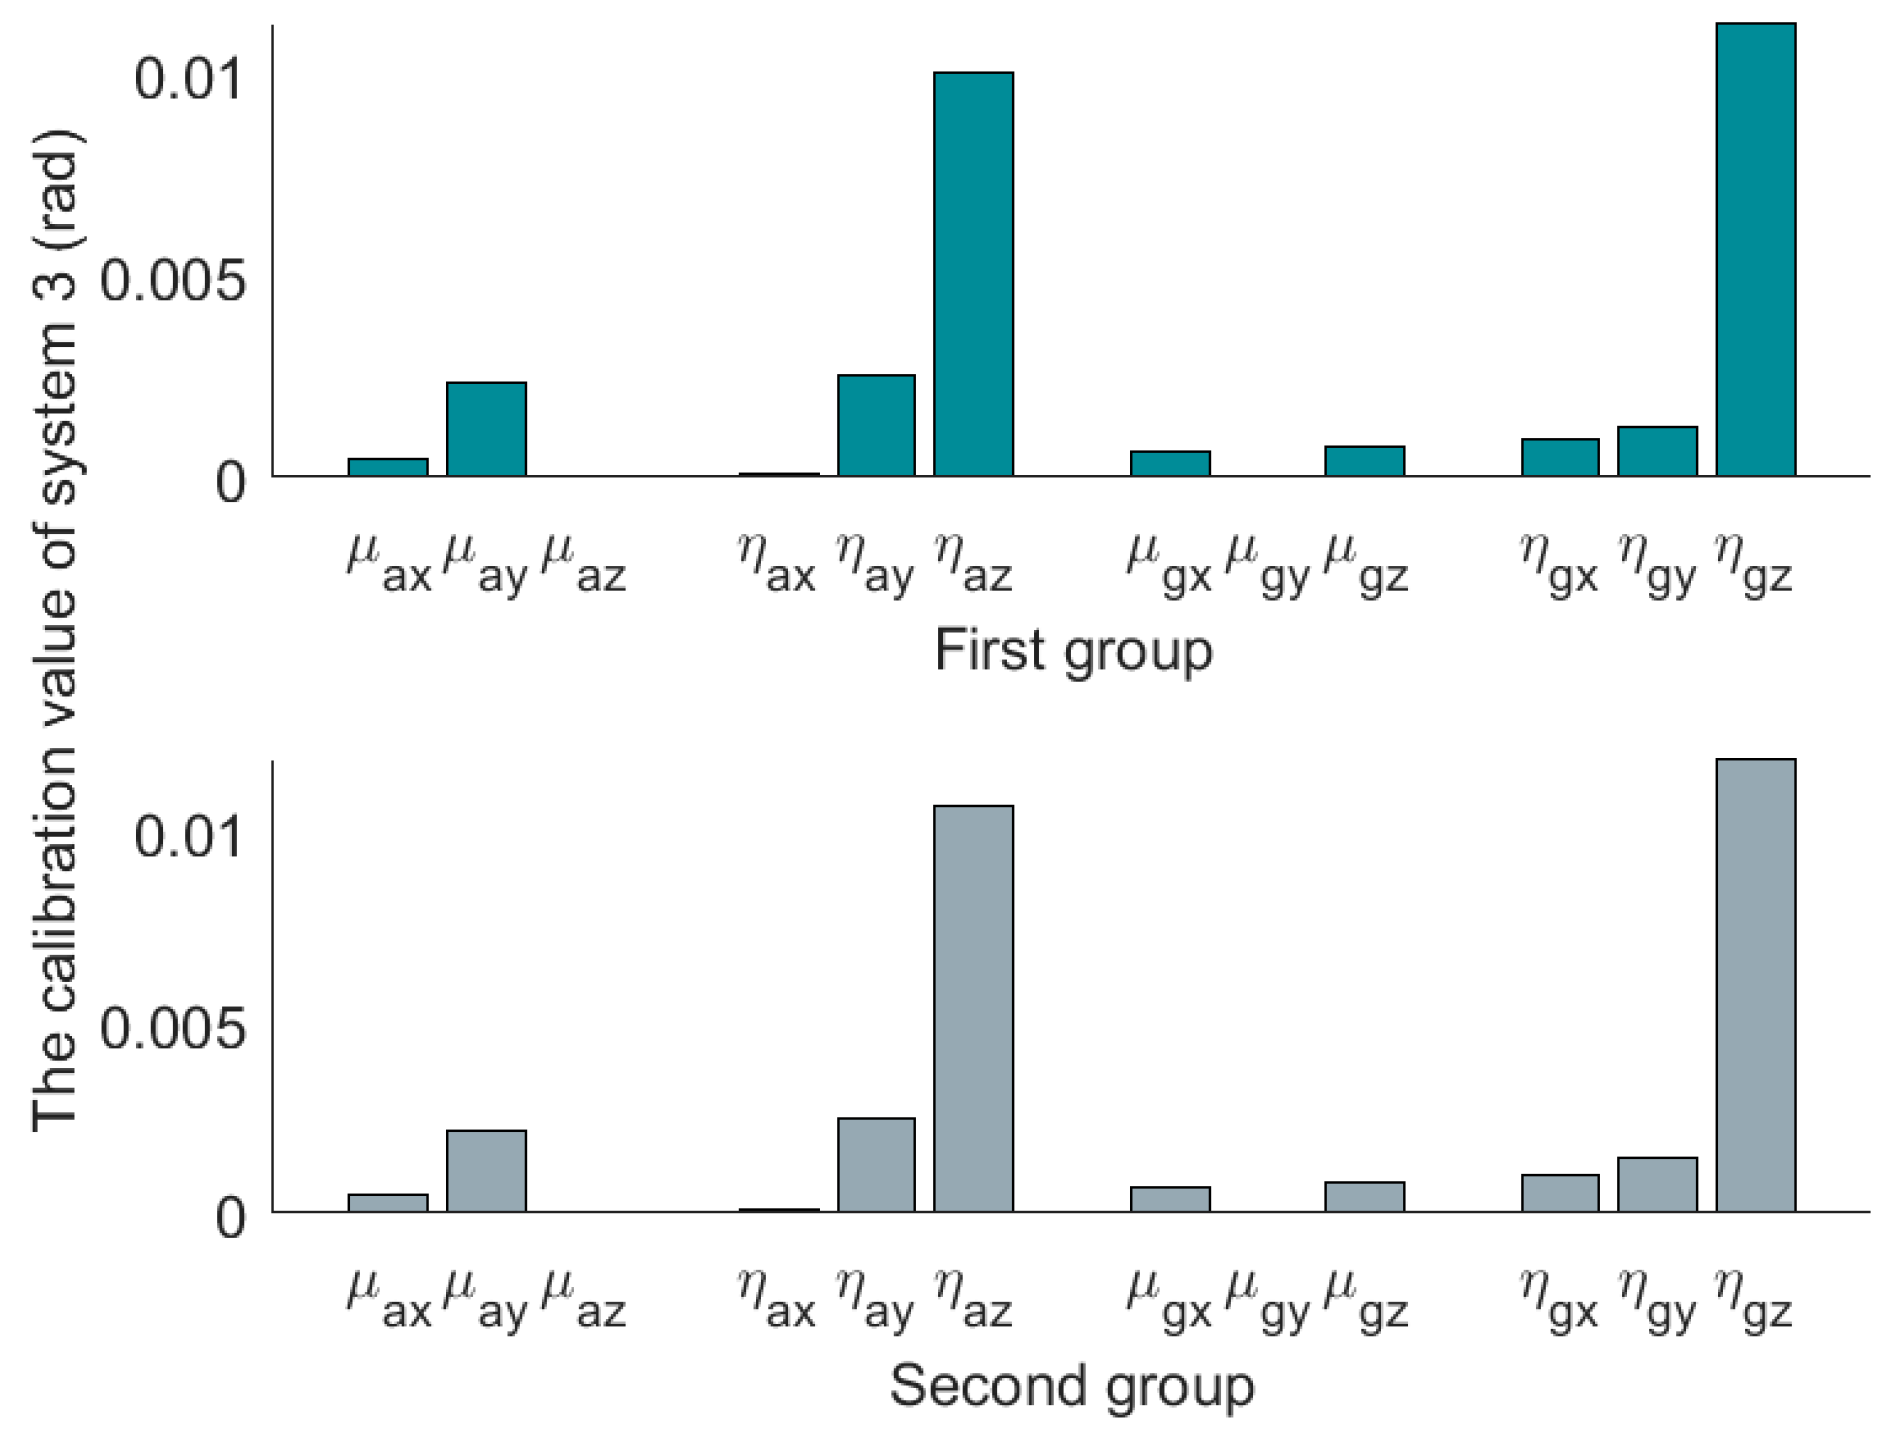
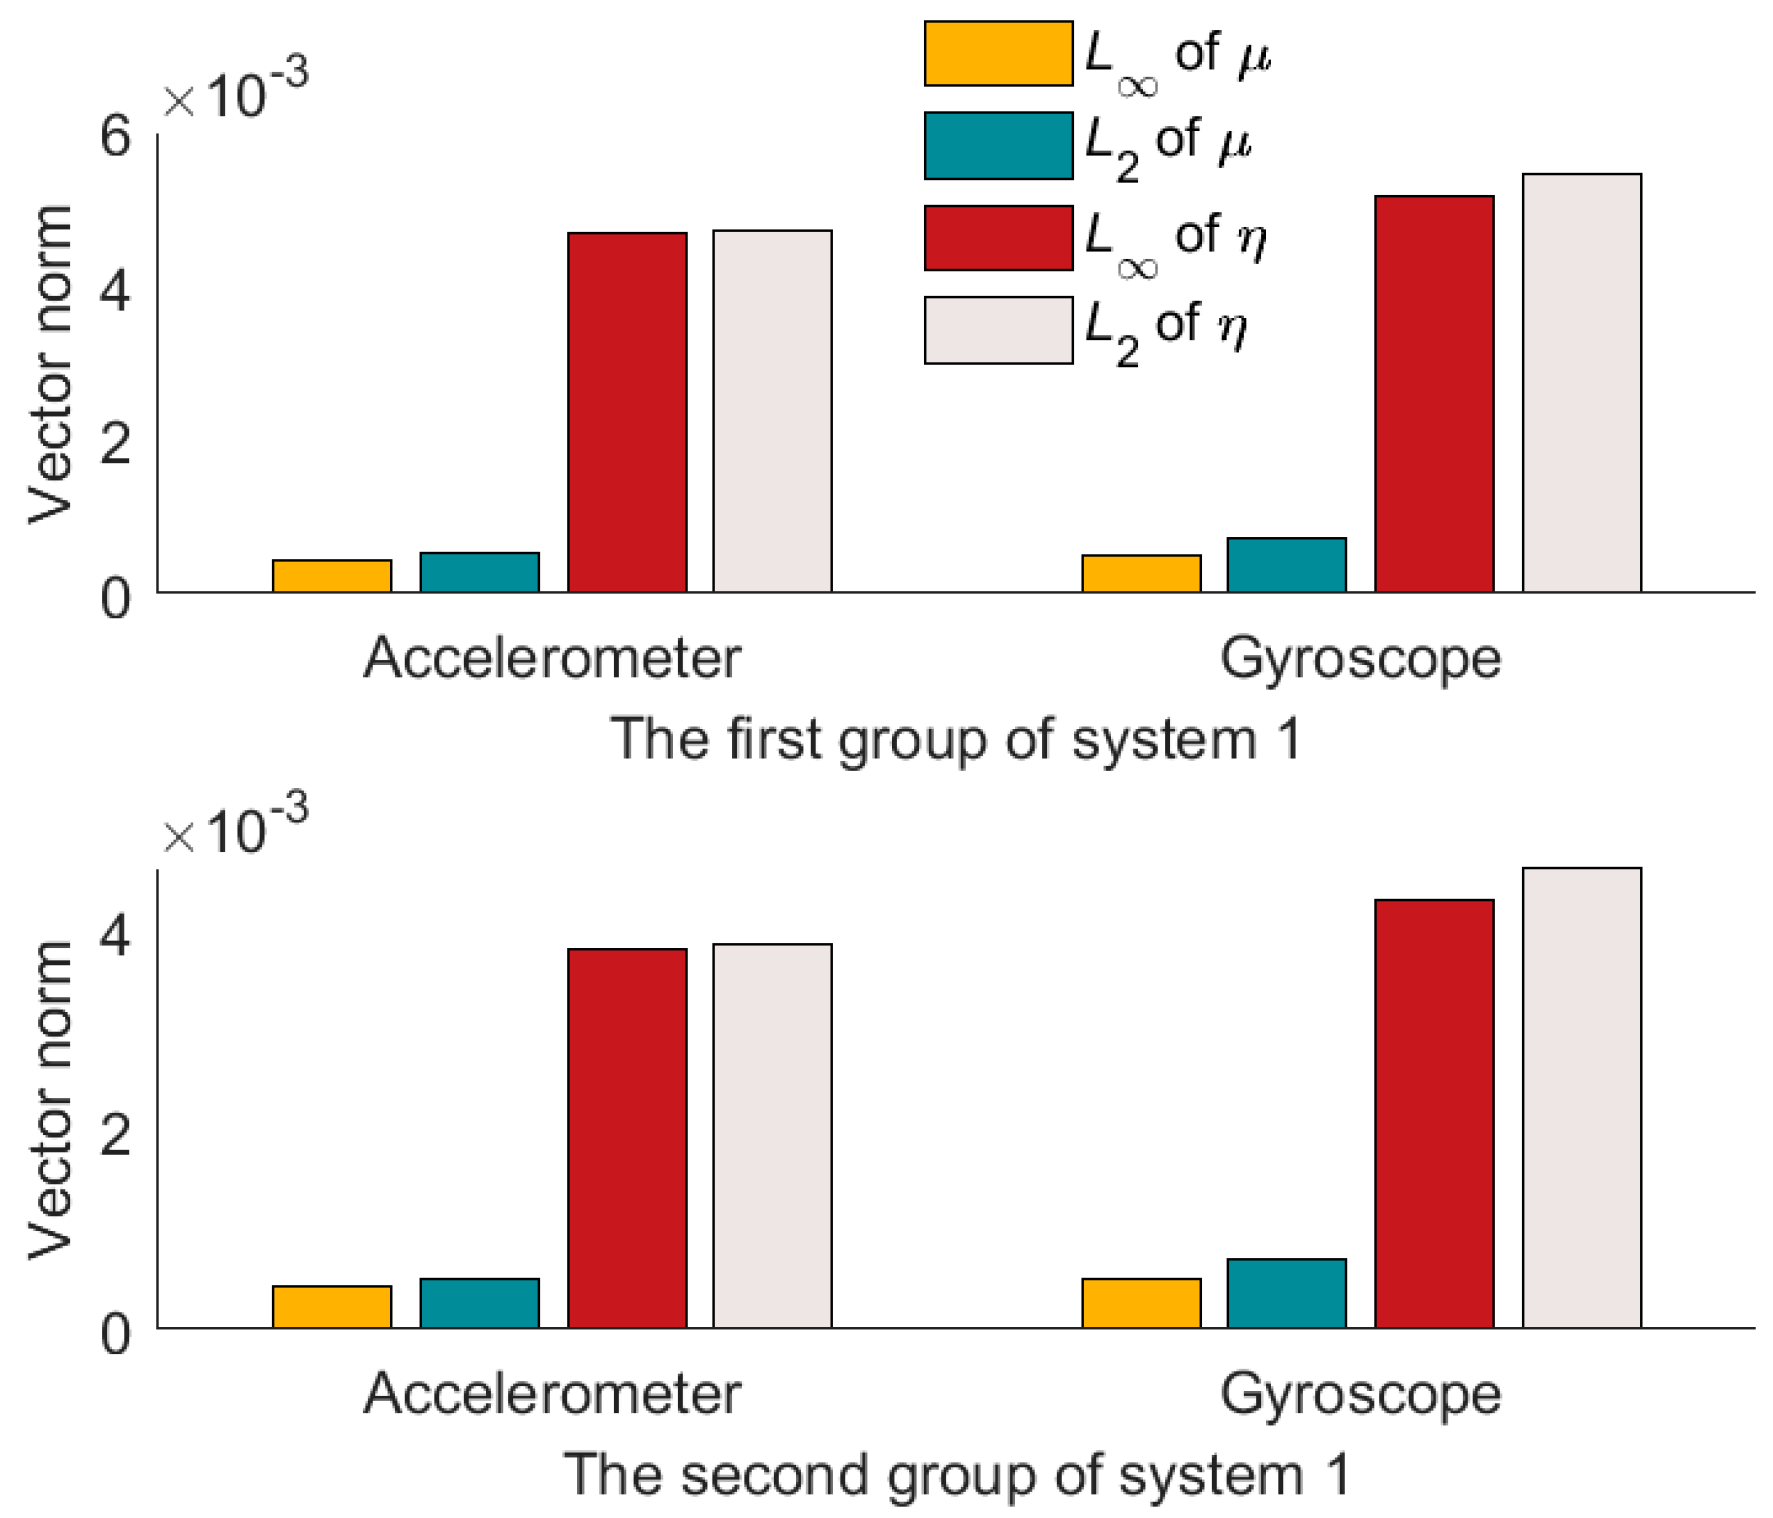
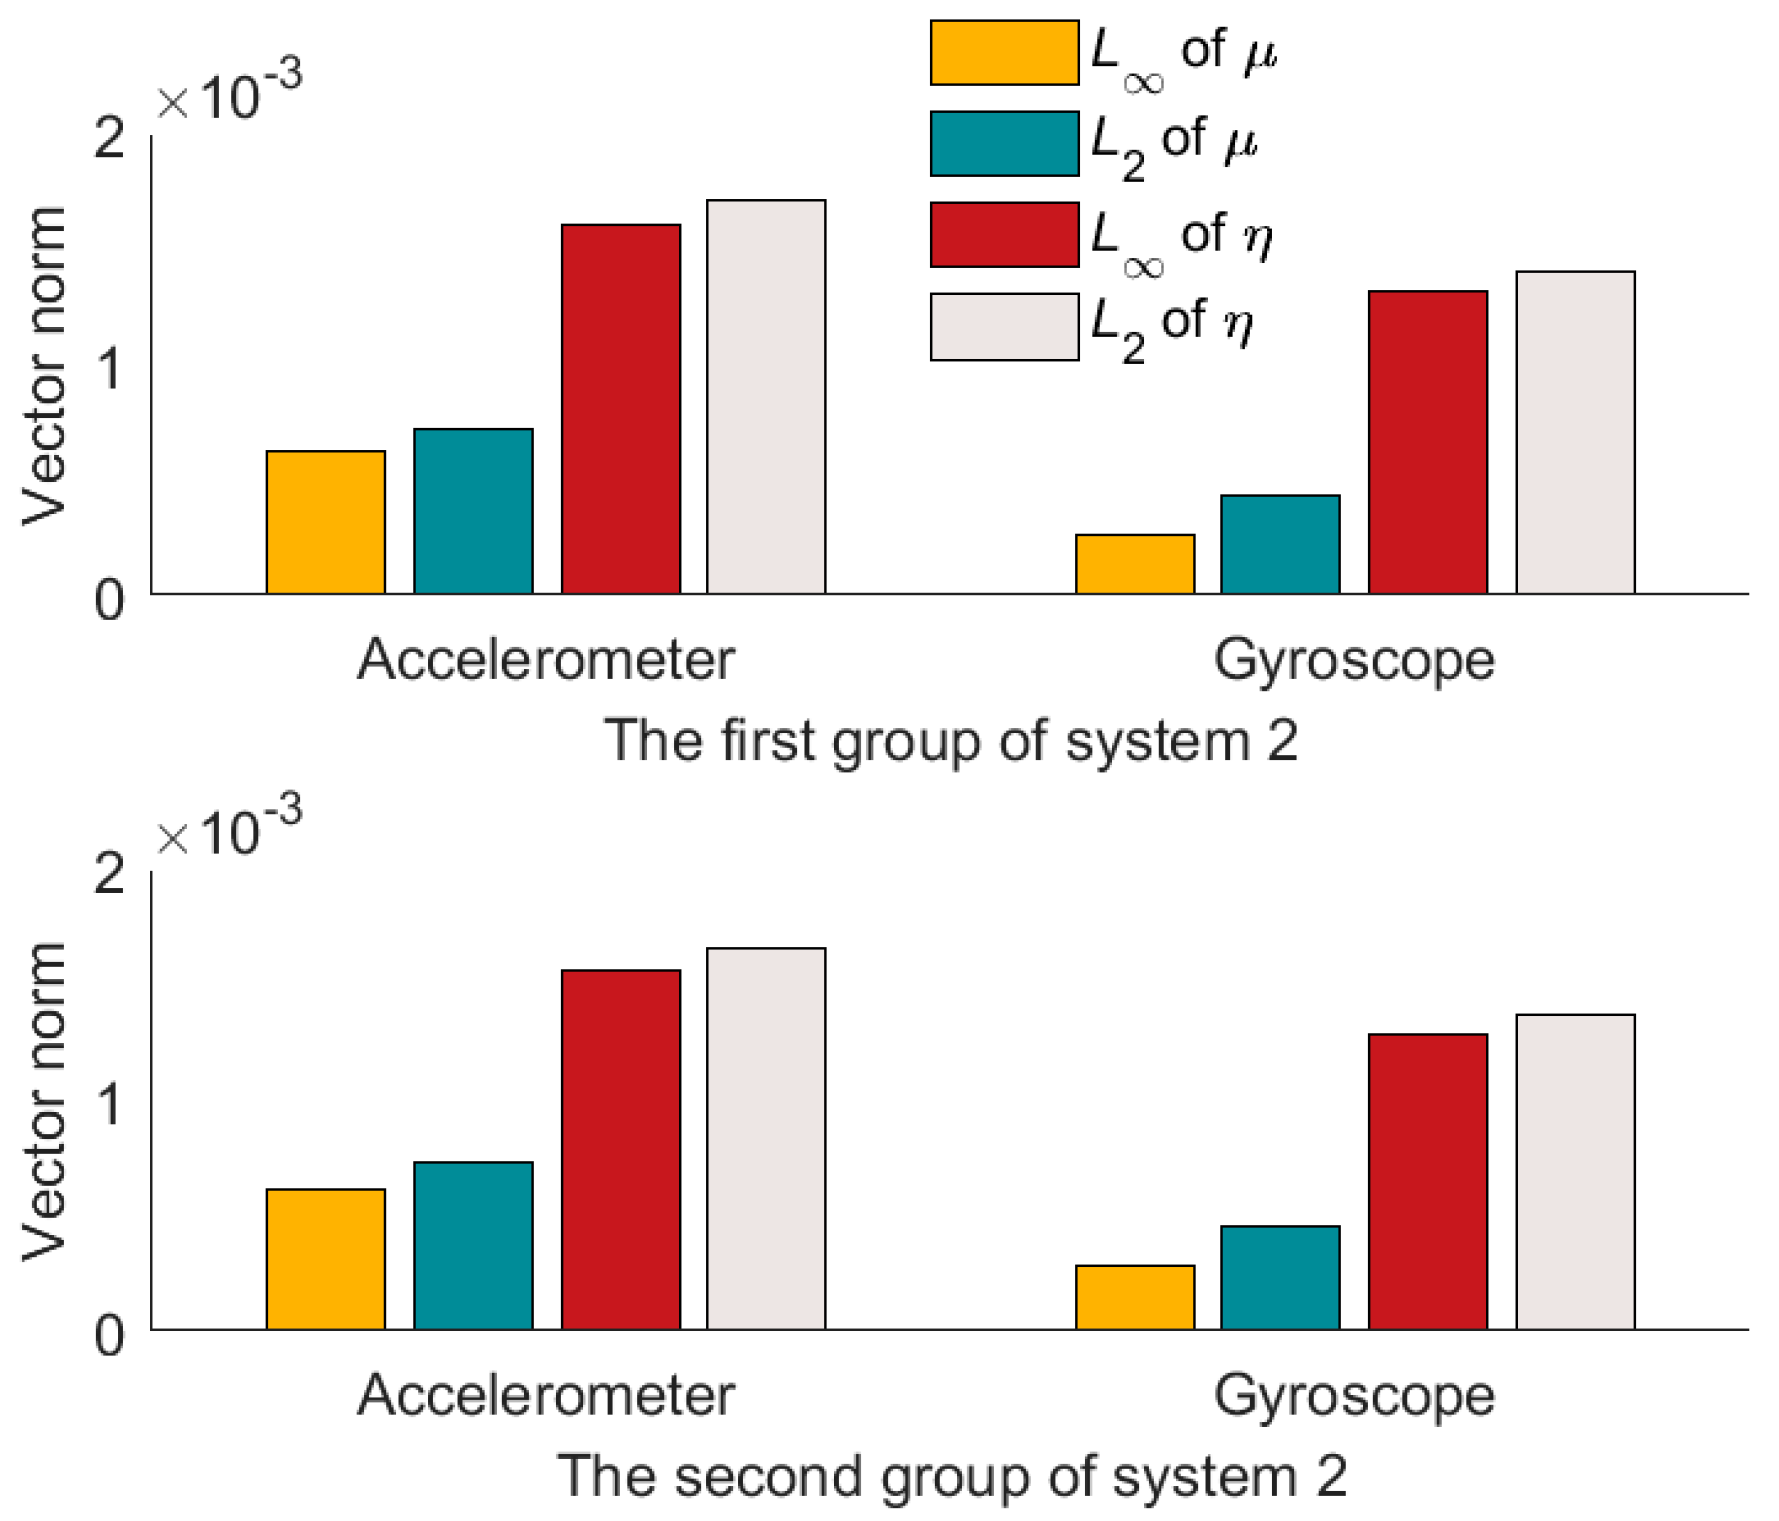
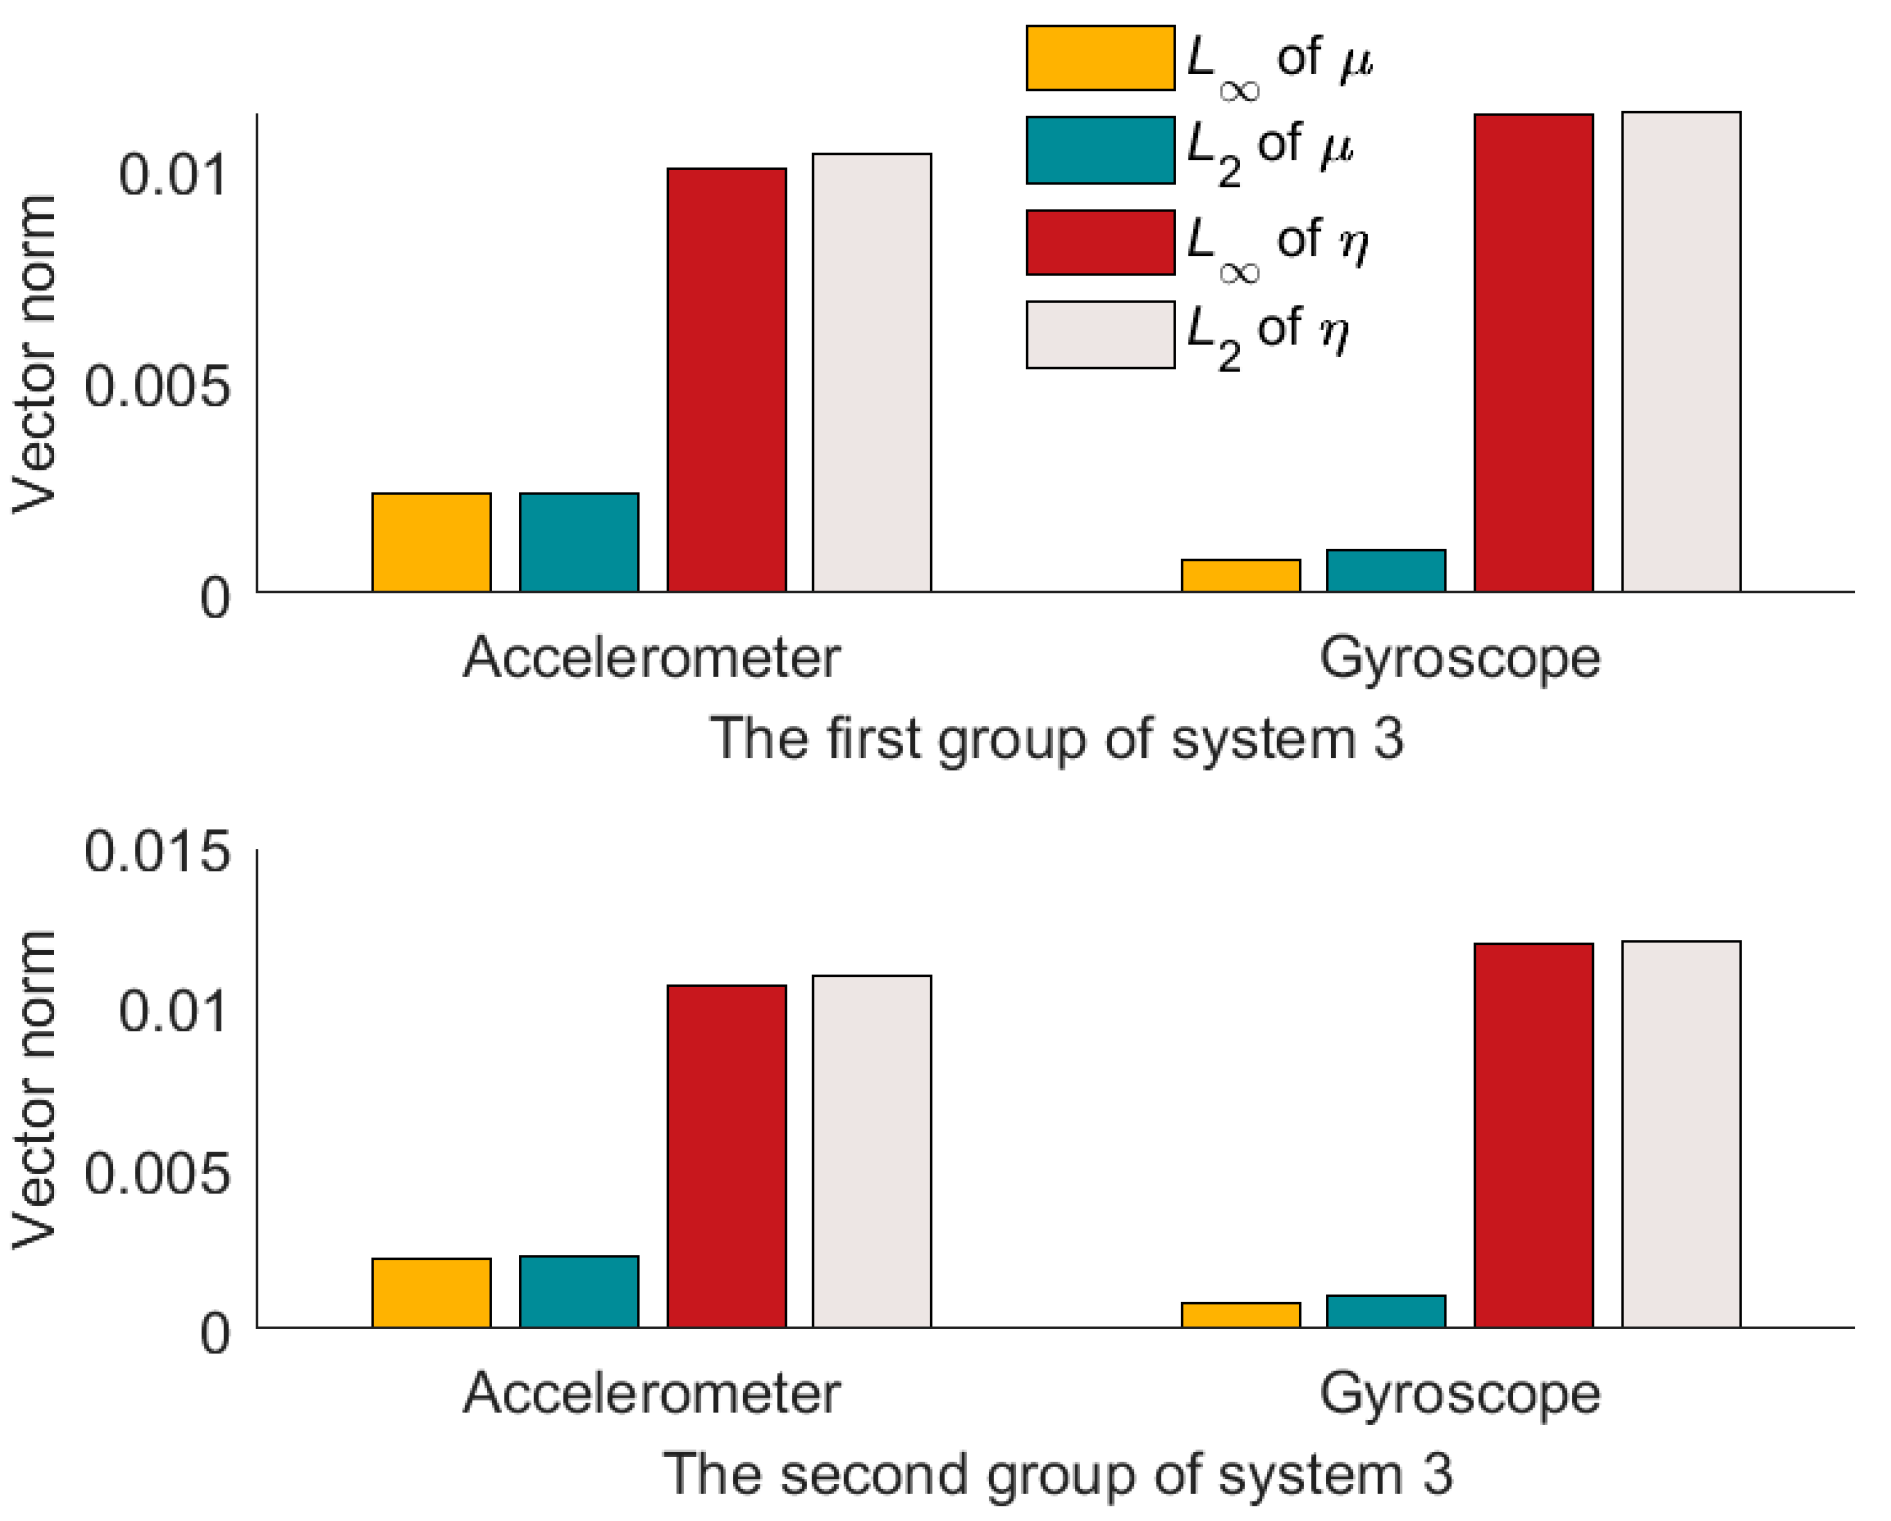
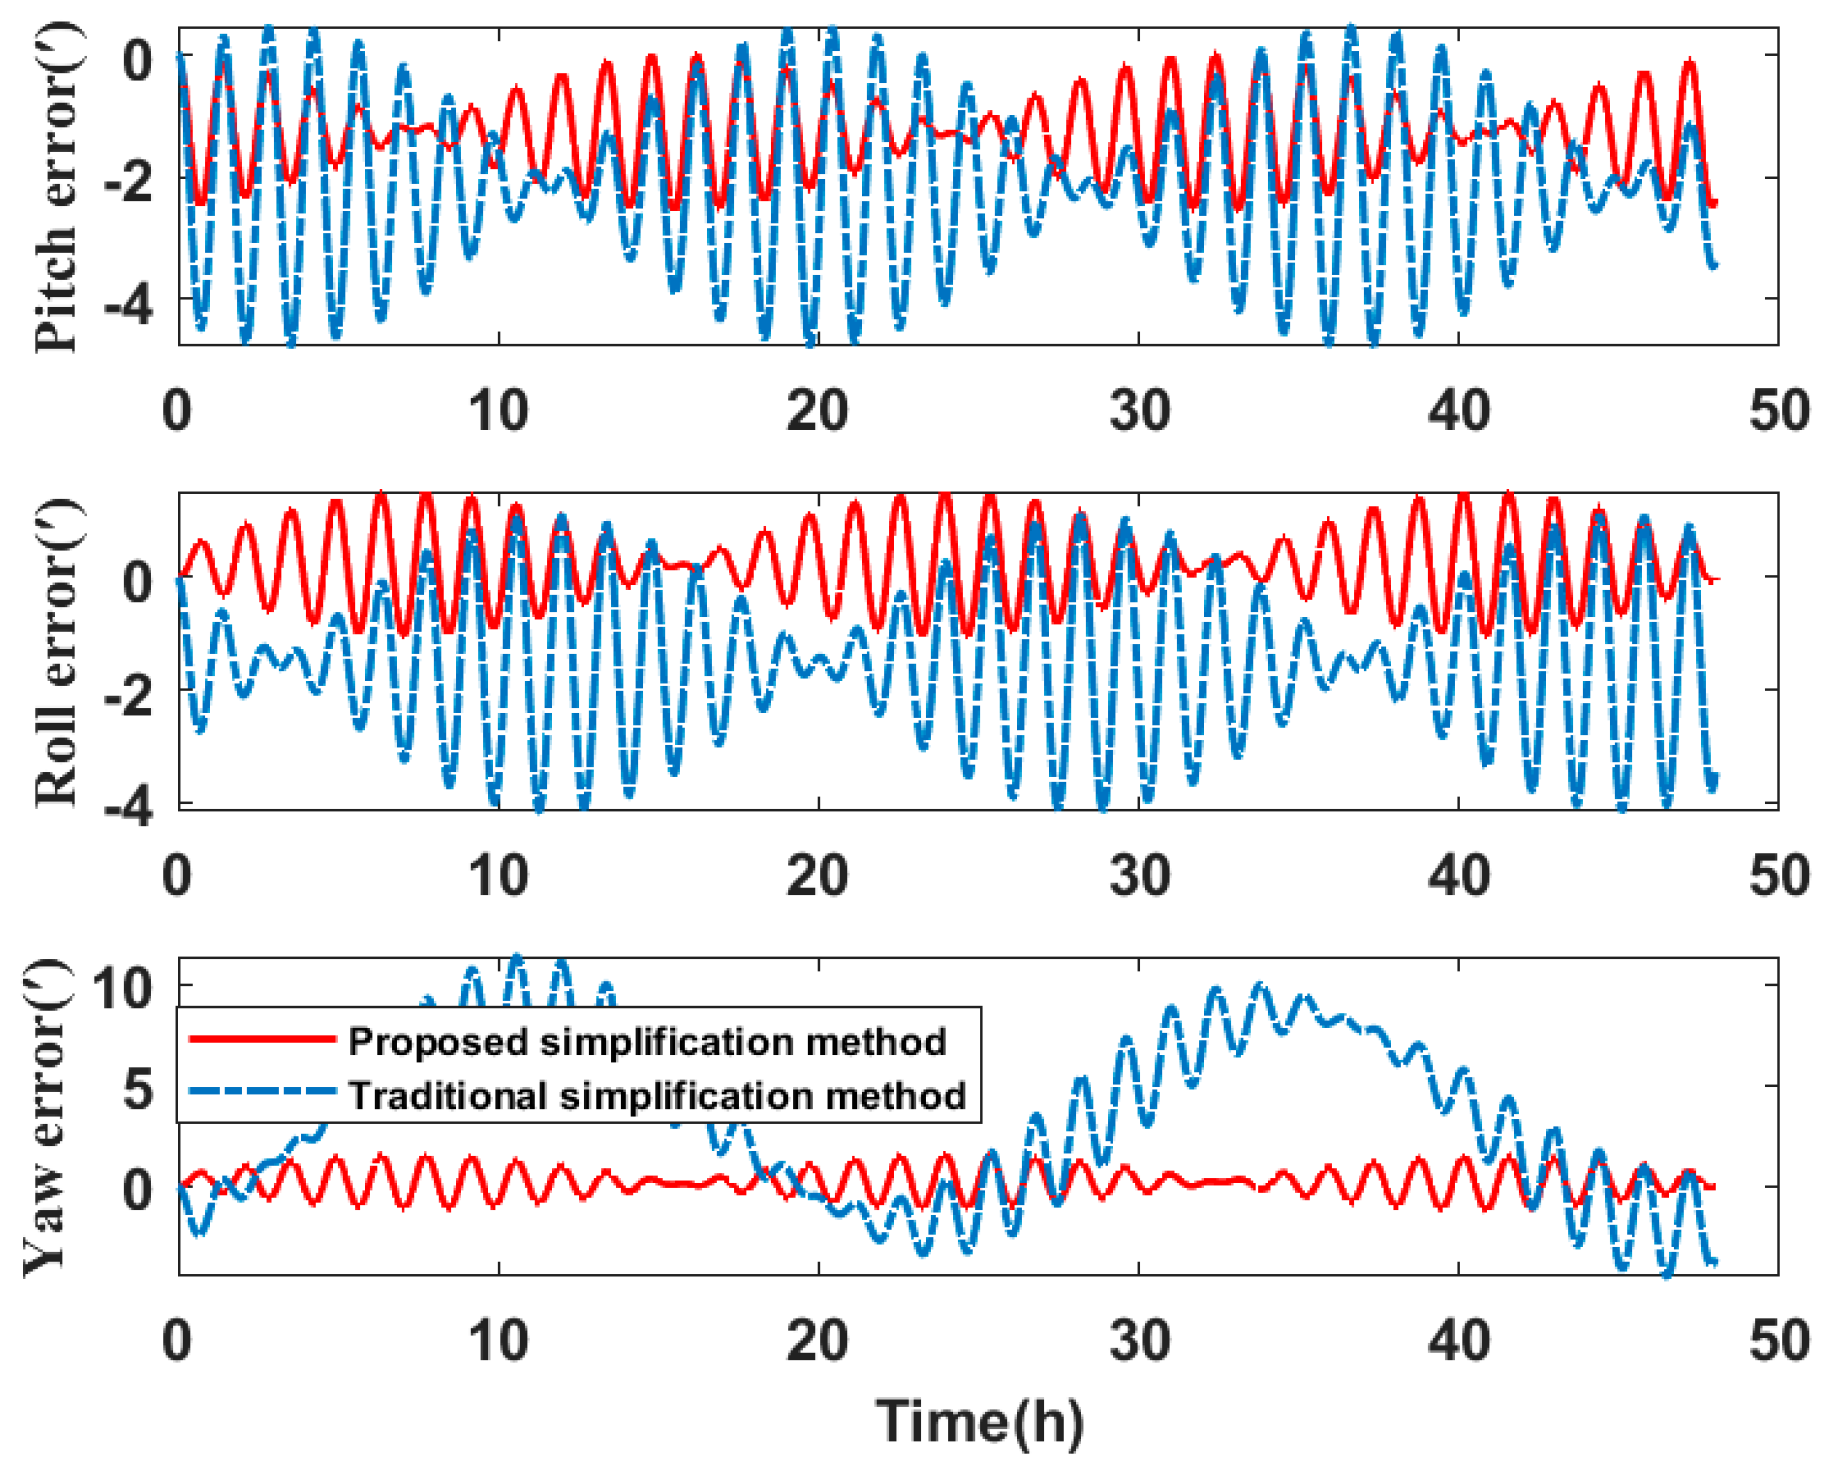
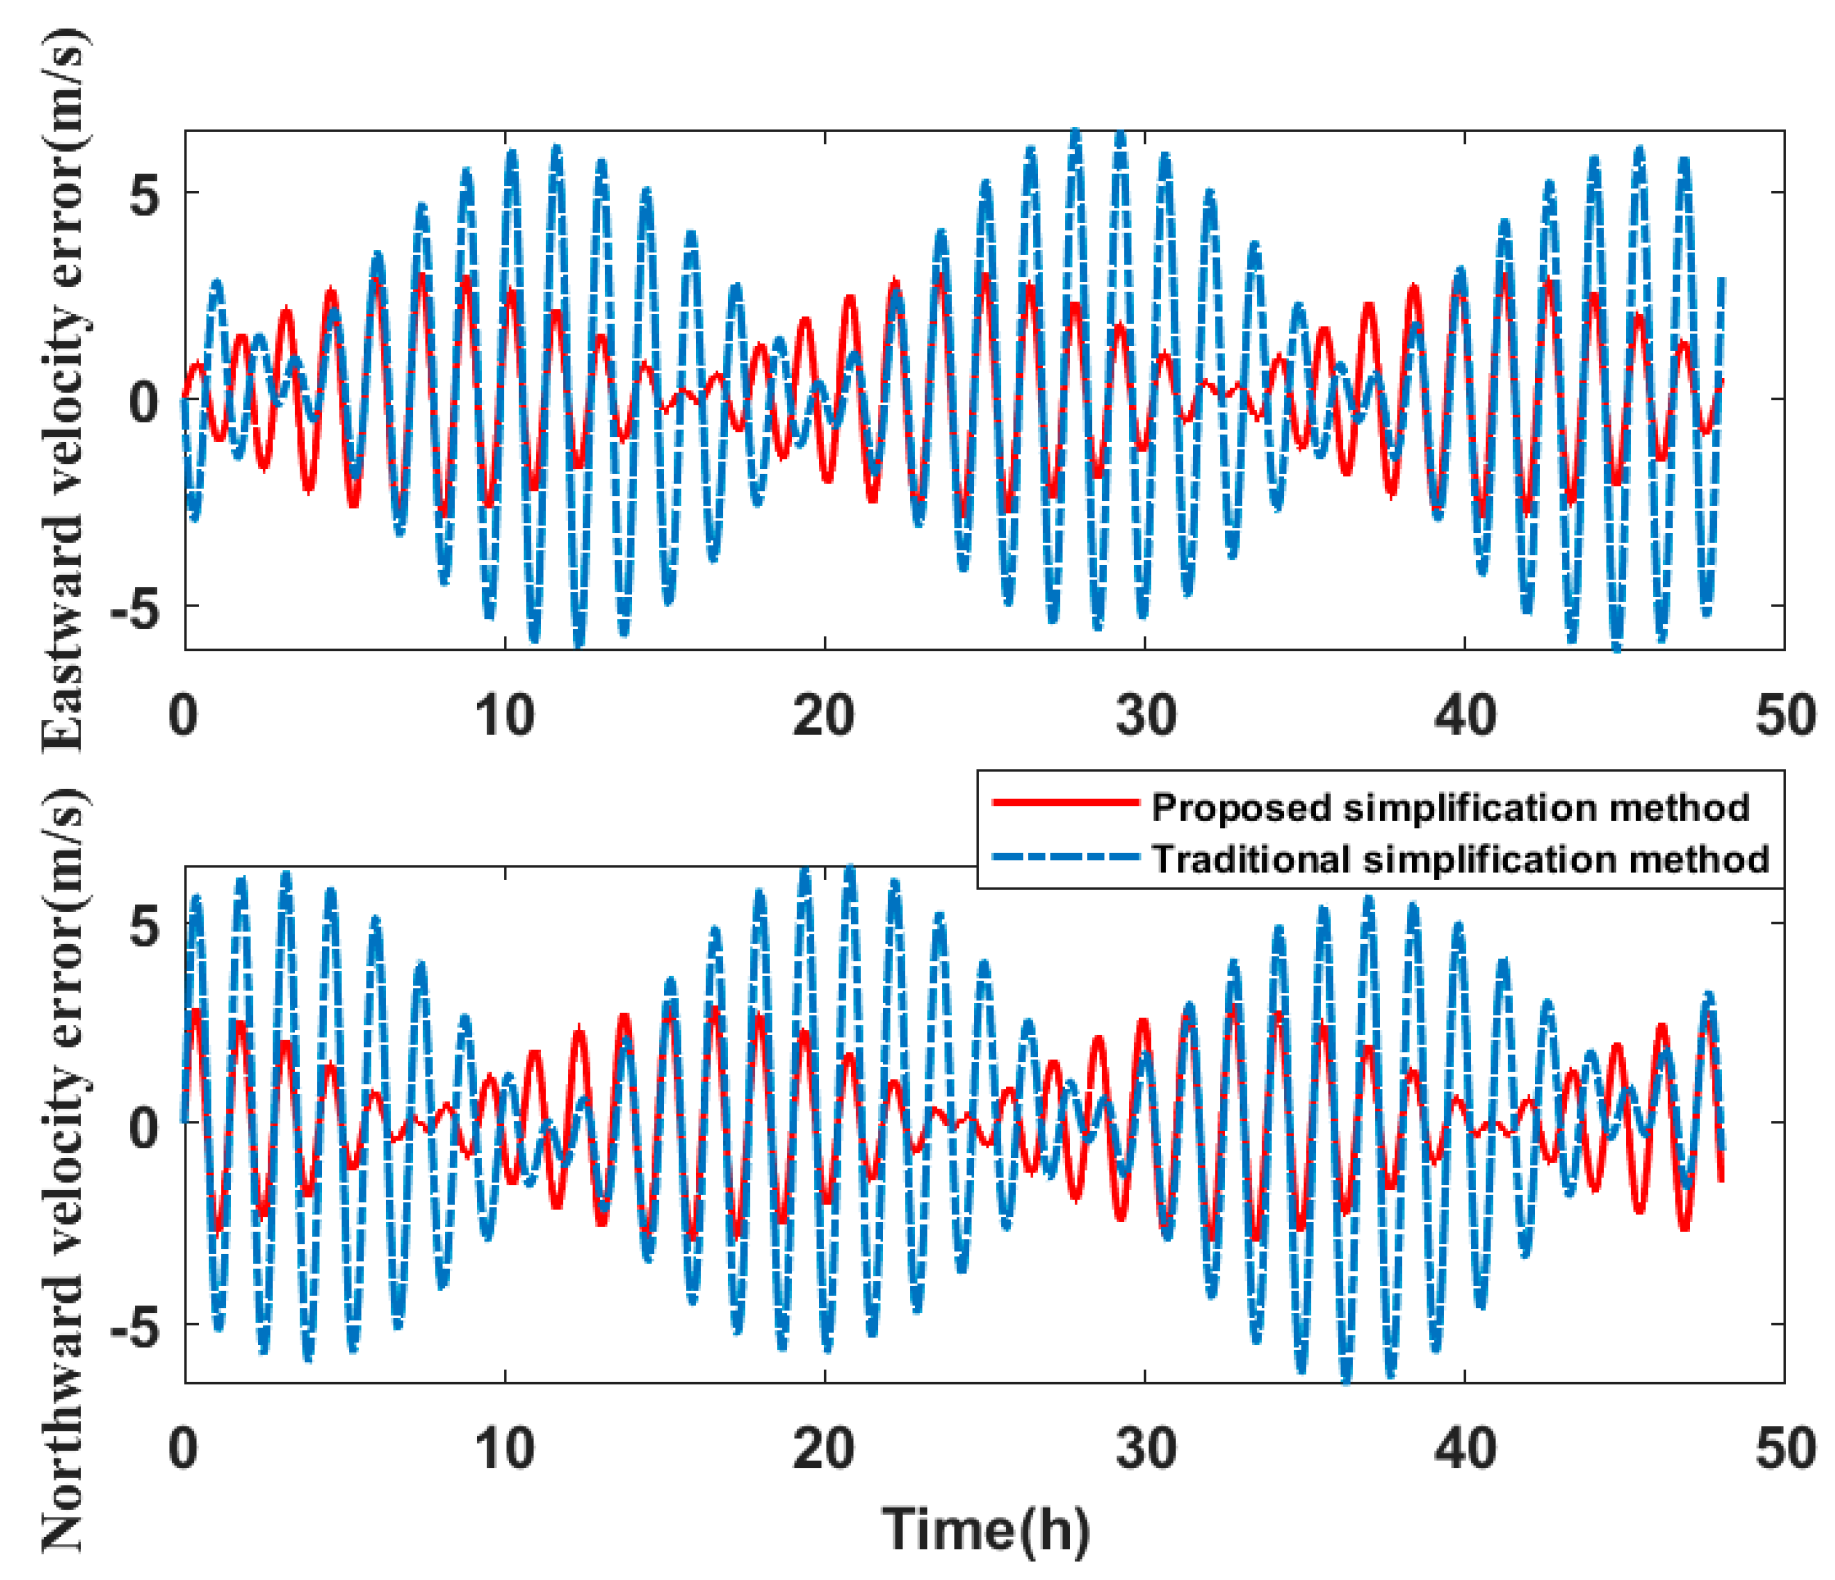
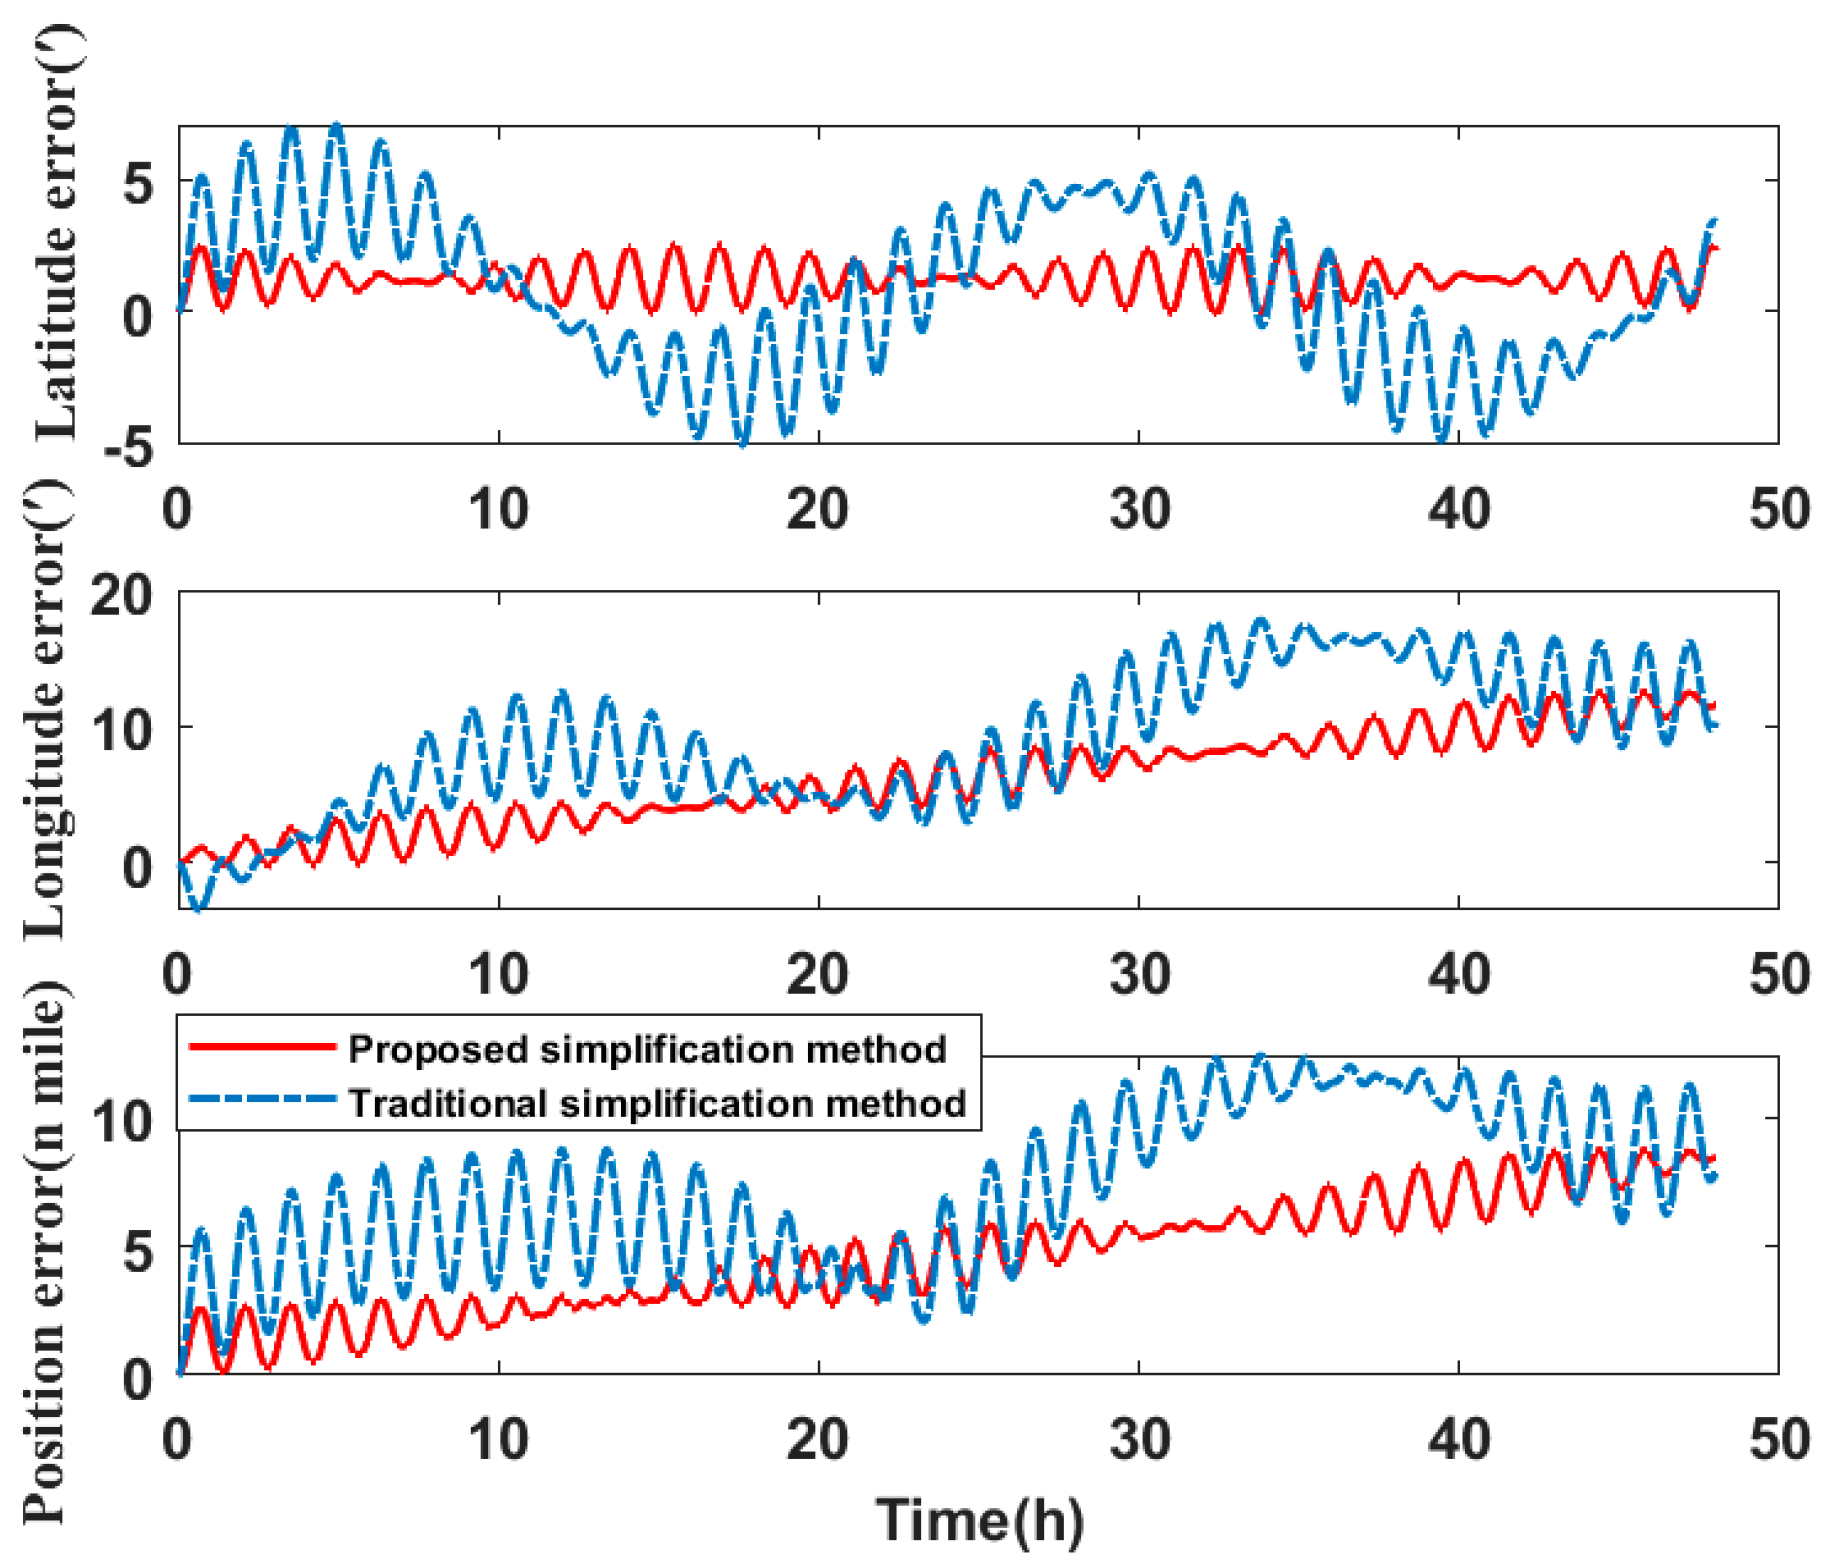
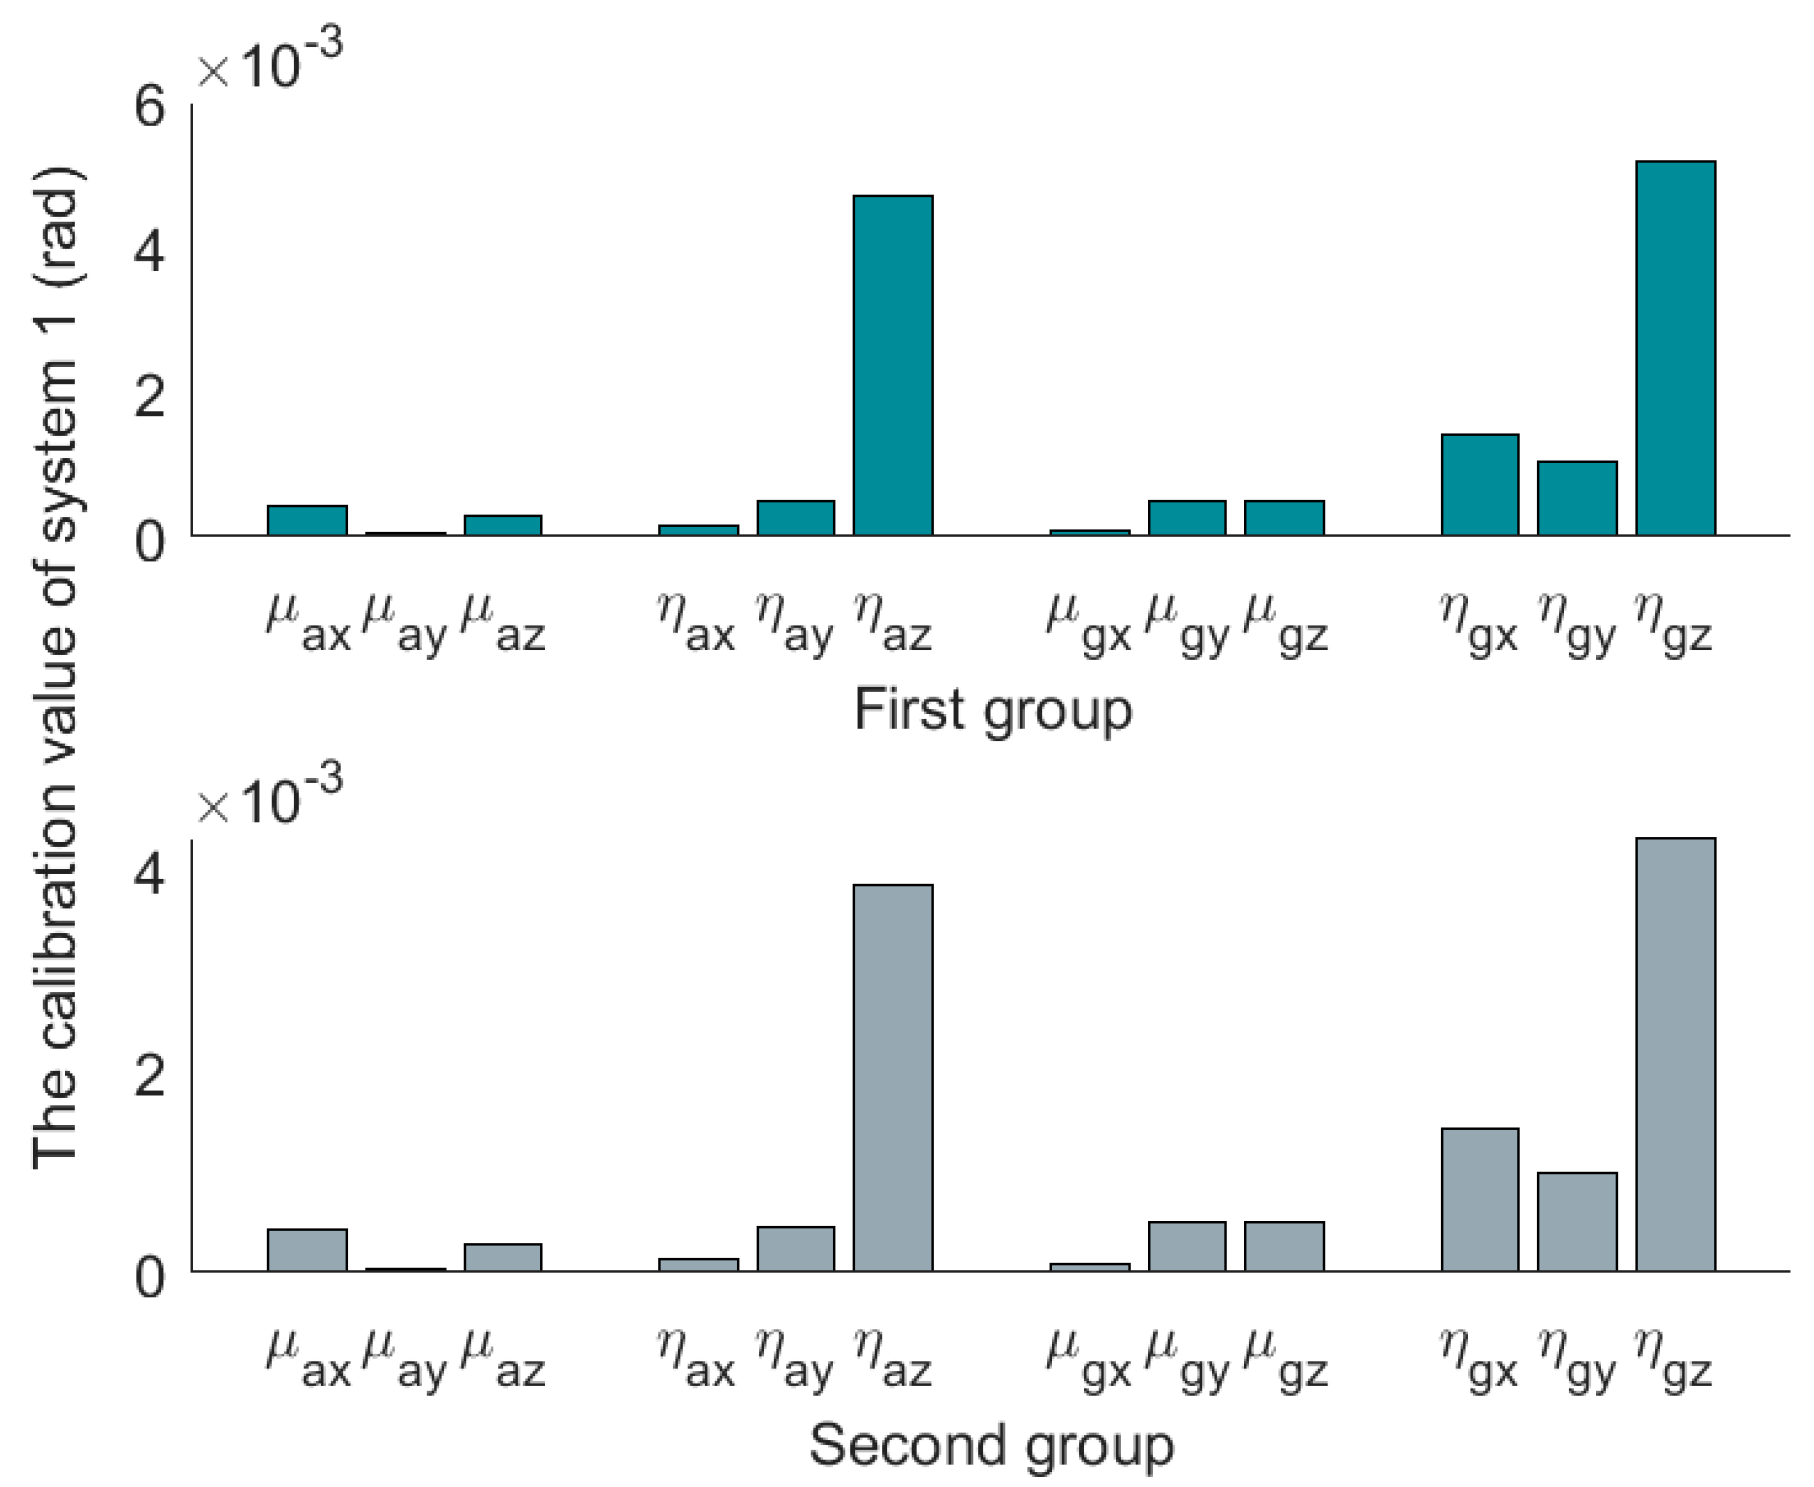
As an important deterministic error of the inertial measurement unit (IMU), the installation error has a serious impact on the navigation accuracy of the strapdown inertial navigation system (SINS). The impact becomes more severe in a highly dynamic application environment. This paper proposes a new IMU calibration model based on polar decomposition. Using the new model, the installation error is decomposed into a nonorthogonal error and a misalignment error. The compensation of the IMU calibration model is decomposed into two steps. First, the nonorthogonal error is compensated, and then the misalignment error is compensated. Based on the proposed IMU calibration model, we used a three-axis turntable to calibrate three sets of strapdown inertial navigation systems (SINS). The experimental results show that the misalignment errors are larger than the nonorthogonal errors. Based on the experimental results, this paper proposes a new method to simplify the installation error. This simplified method defines the installation error matrix as an antisymmetric matrix composed of three misalignment errors. The navigation errors caused by the proposed simplified calibration model are compared with the navigation errors caused by the traditional simplified calibration model. The 48-h navigation experiment results show that the proposed simplified calibration model is superior to the traditional simplified calibration model in attitude accuracy, velocity accuracy, and position accuracy.
Keywords: IMU; calibration; polar decomposition; nonorthogonal error; misalignment error; installation error model IMU; calibration; polar decomposition; nonorthogonal error; misalignment error; installation error model