Article

A Method for the Automatic Extraction of Support Devices in an Overhead Catenary System Based on MLS Point Clouds

1
School of Remote Sensing and Information Engineering, Wuhan University, Wuhan 430079, China
2
China Transport Telecommunications & Information Center, Beijing 100011, China
3
Center for Health Statistics and Information, National Health Commission of the People’s Republic of China, Beijing 100044, China
*
Author to whom correspondence should be addressed.
Remote Sens. 2022, 14(23), 5915; https://doi.org/10.3390/rs14235915
Submission received: 19 October 2022 / Revised: 15 November 2022 / Accepted: 19 November 2022 / Published: 22 November 2022

Abstract

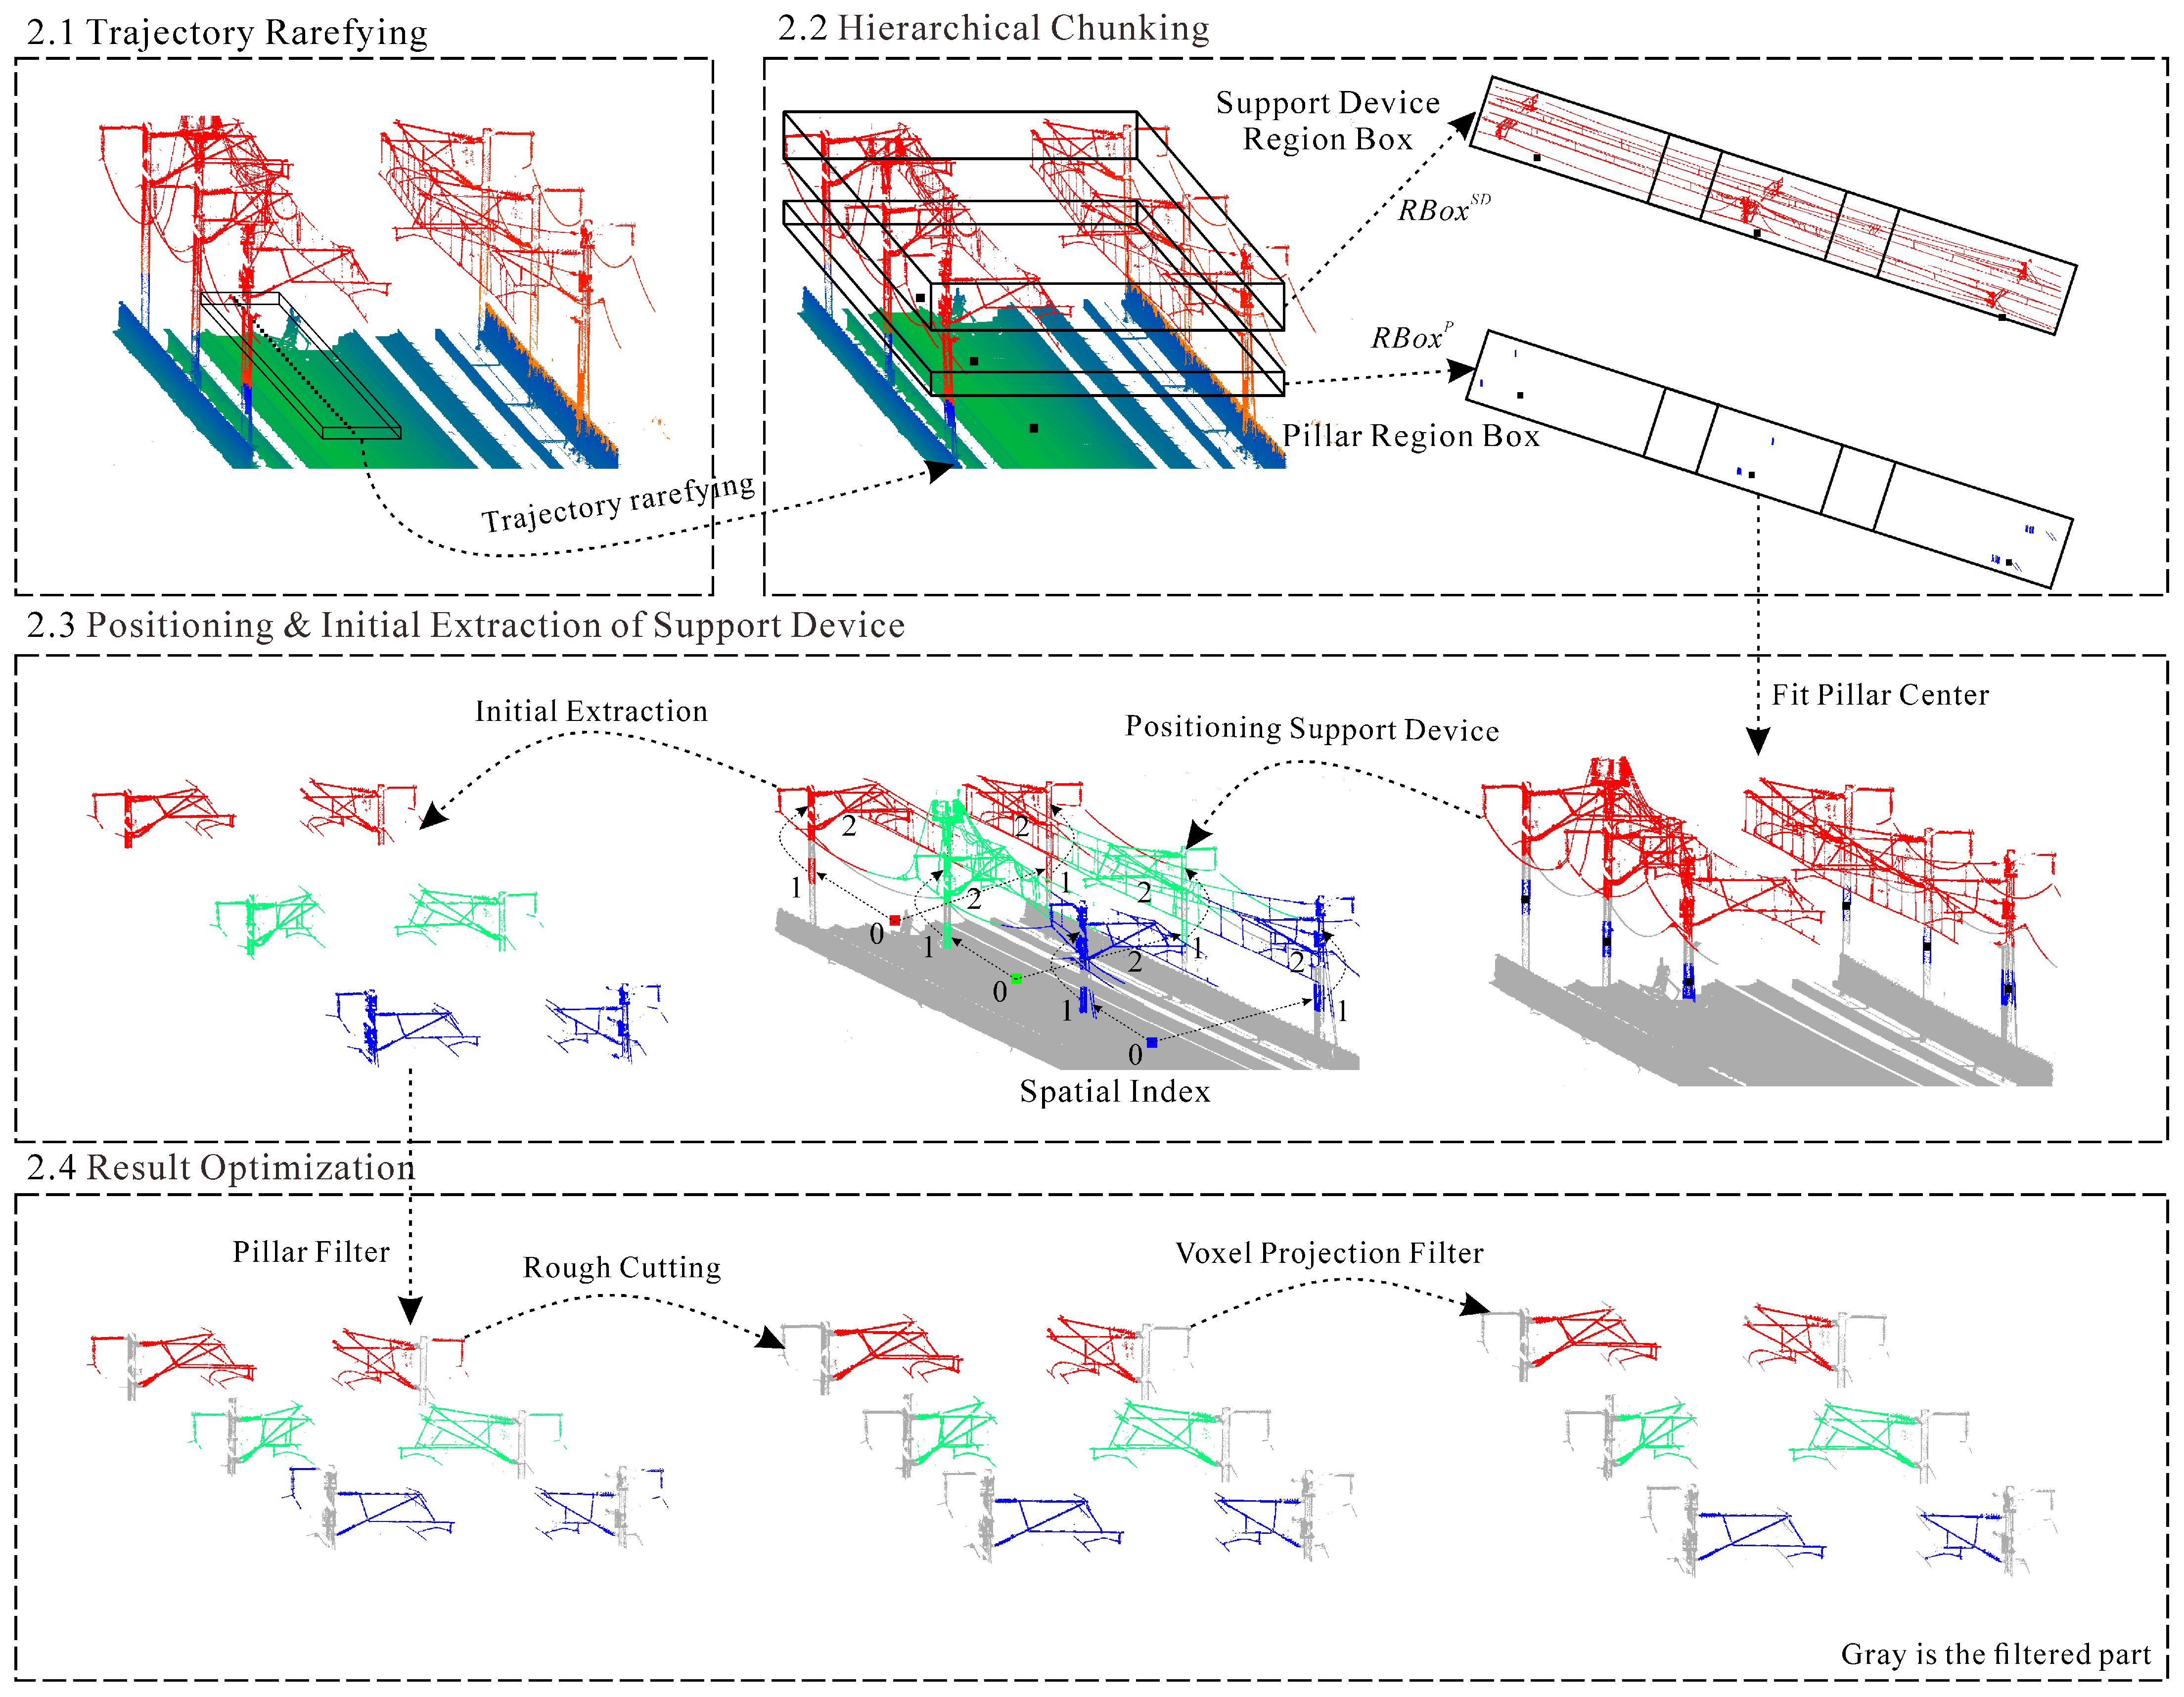
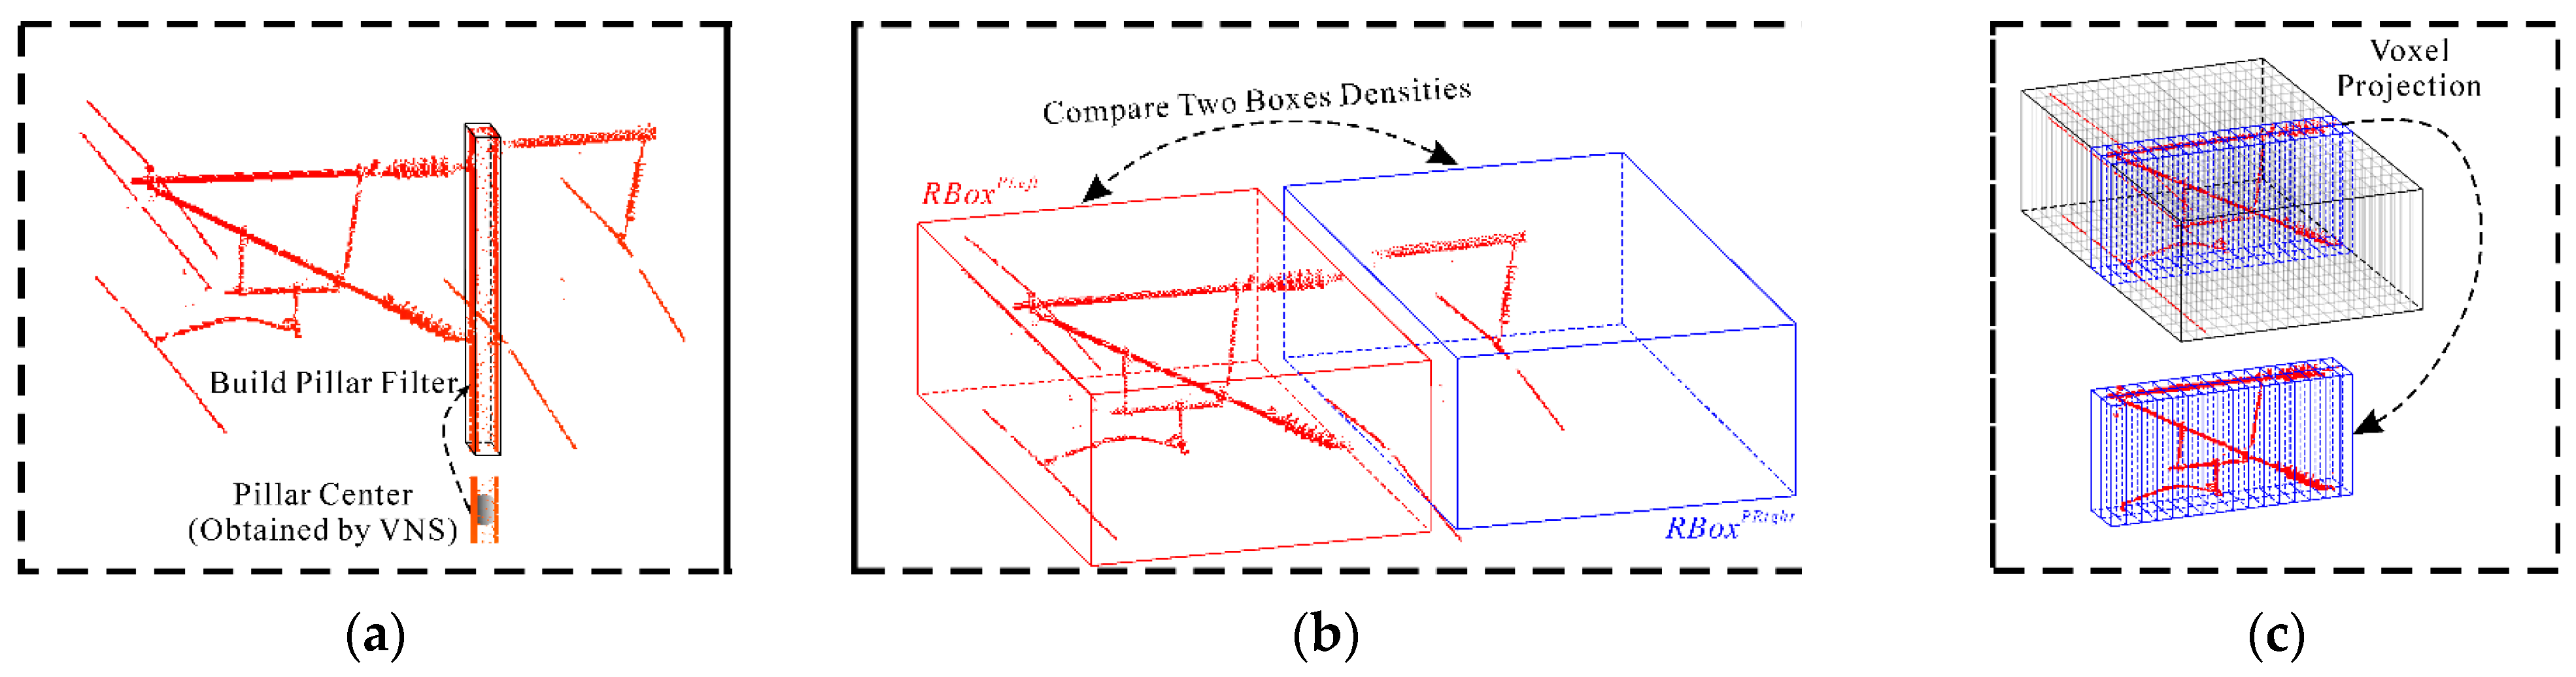
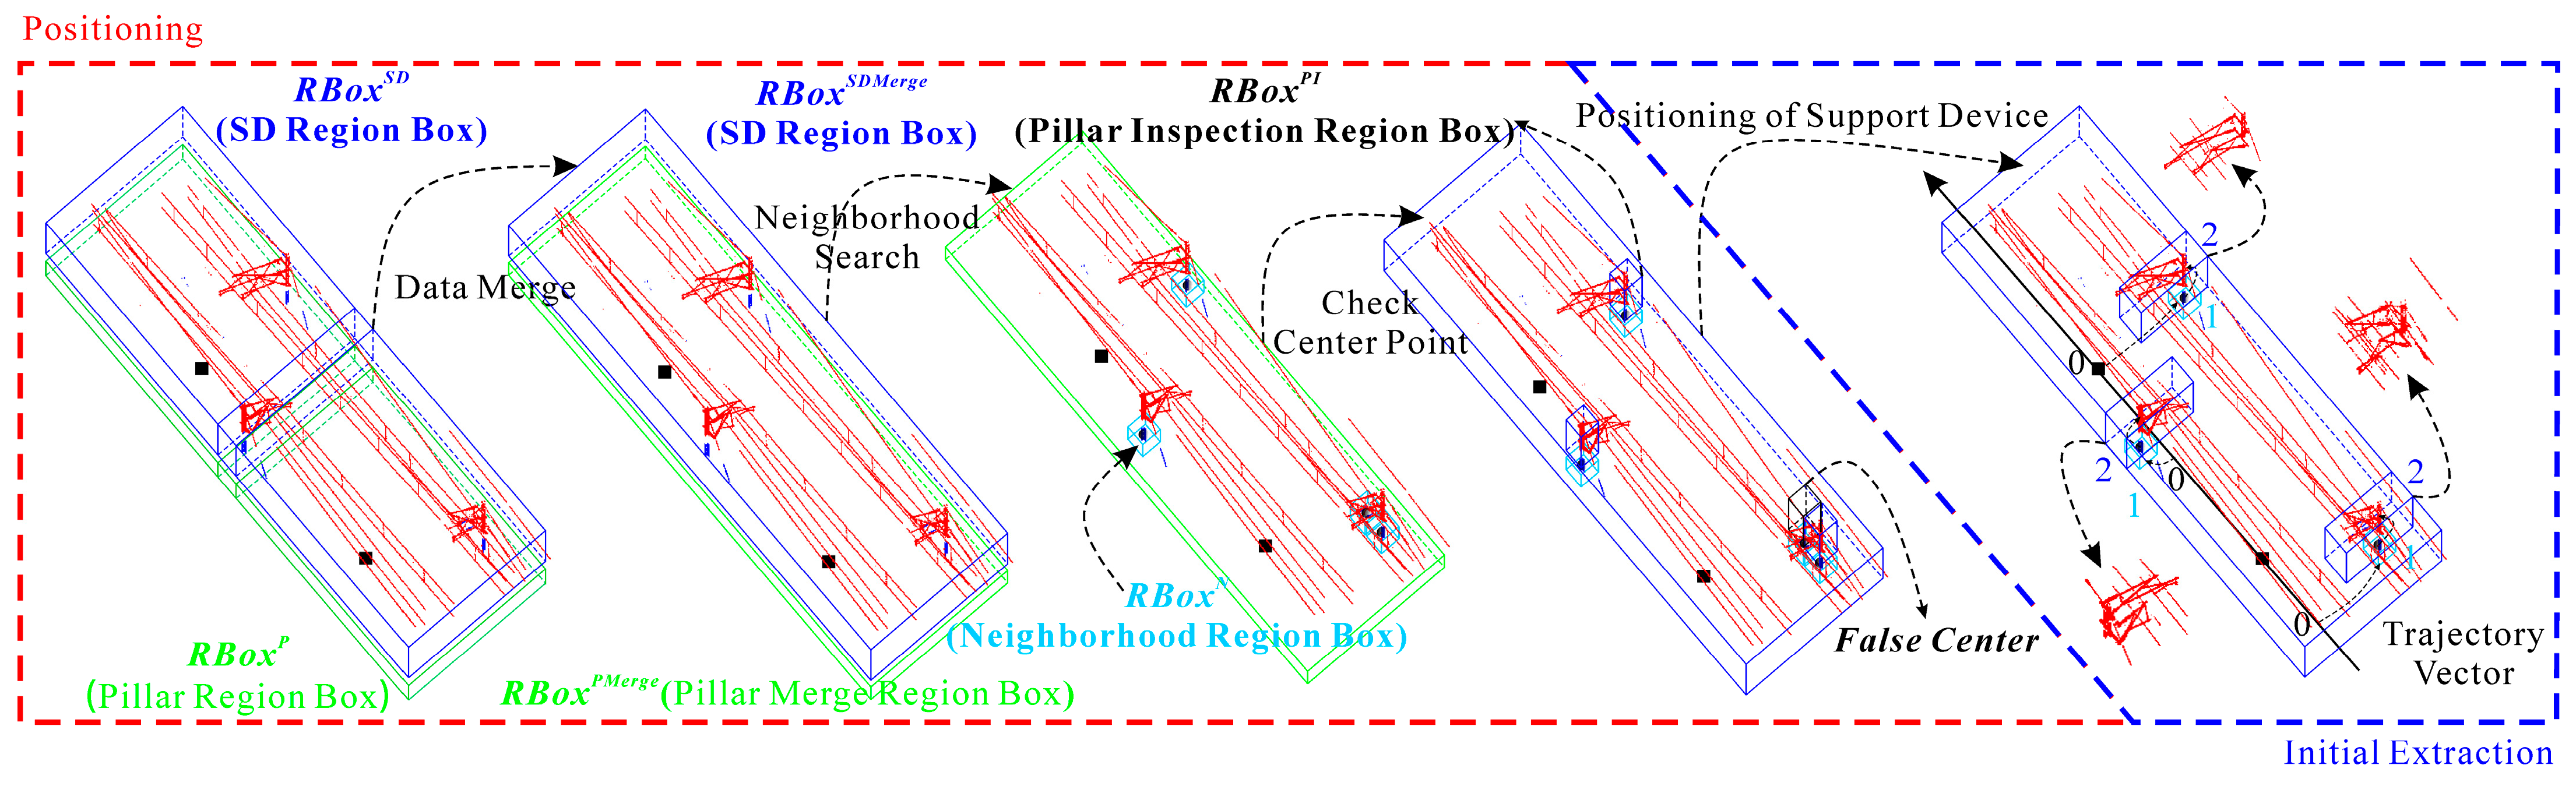
A mobile laser scanning (MLS) system can acquire railway scene information quickly and provide a data foundation for regular railway inspections. The location of the catenary support device in an electrified railway system has a direct impact on the regular operation of the power supply system. However, multi-type support device data accounts for a tiny proportion of the whole railway scene, resulting in its poor characteristic expression in the scene. Therefore, using traditional point cloud filtering or point cloud segmentation methods alone makes it difficult to achieve an effective segmentation and extraction of the support device. As a result, this paper proposes an automatic extraction algorithm for complex railway support devices based on MLS point clouds. First, the algorithm obtains hierarchies of the pillar point clouds and the support device point clouds in the railway scene through high stratification and then realizes the noise that was point-cloud-filtered in the scene. Then, the center point of the pillar device is retrieved from the pillar corridor by a neighborhood search, and then the locating and initial extracting of the support device are realized based on the relatively stable spatial topological relationship between the pillar and the support device. Finally, a post-processing optimization method integrating the pillar filter and the voxelized projection filter is designed to achieve the accurate and efficient extraction of the support device based on the feature differences between the support device and other devices in the initial extraction results. Furthermore, in the experimental part, we evaluate the treatment effect of the algorithm in six types of support devices, three types of support device distribution scenes, and two types of railway units. The experimental results show that the average extraction IoU of the multi-type support device, support device distribution scenes, and railway unit were 97.20%, 94.29%, and 96.11%, respectively. In general, the proposed algorithm can achieve the accurate and efficient extraction of various support devices in different scenes, and the influence of the algorithm parameters on the extraction accuracy and efficiency is elaborated in the discussion section.
Keywords: overhead catenary system support device; mobile laser scanning; hierarchical chunking; target extraction; integrated filter overhead catenary system support device; mobile laser scanning; hierarchical chunking; target extraction; integrated filter