Article

Research on Control Method of Dual-Motor Load Simulator

College of Electronic Information and Automation, Civil Aviation University of China, Tianjin 300300, China
*
Author to whom correspondence should be addressed.
World Electr. Veh. J. 2023, 14(2), 28; https://doi.org/10.3390/wevj14020028
Submission received: 2 December 2022 / Revised: 15 January 2023 / Accepted: 18 January 2023 / Published: 23 January 2023
(This article belongs to the Special Issue Electrical Machines Design and Control in Electric Vehicles)

Abstract

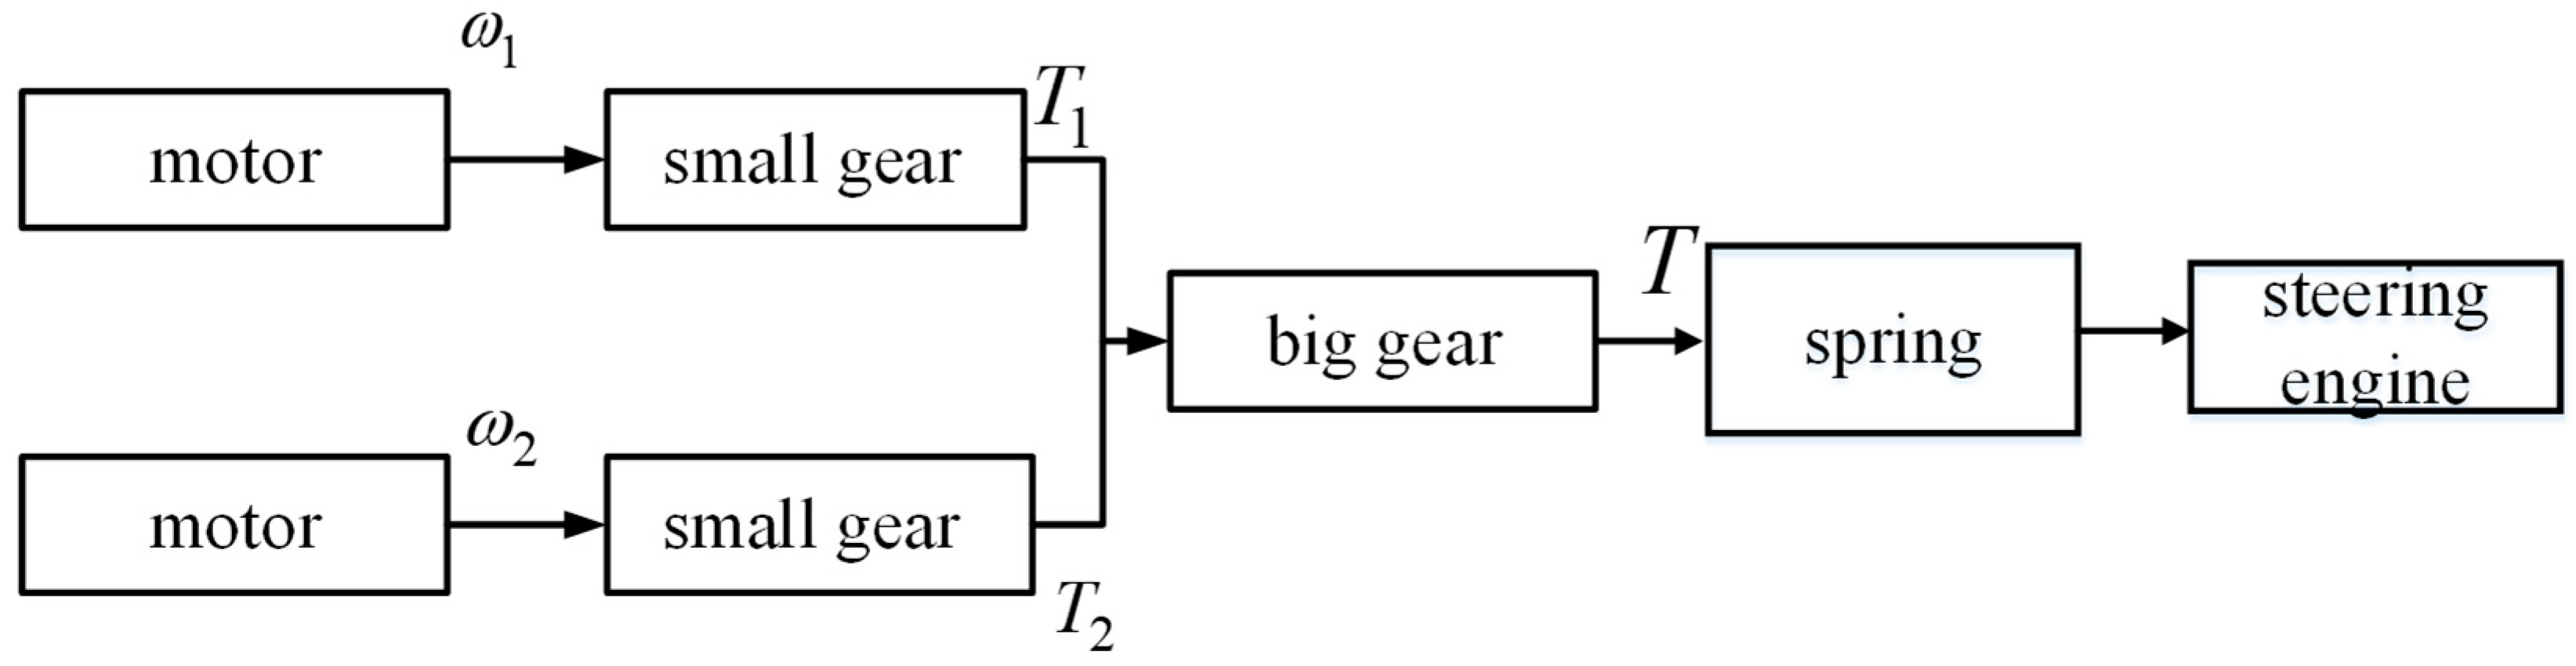
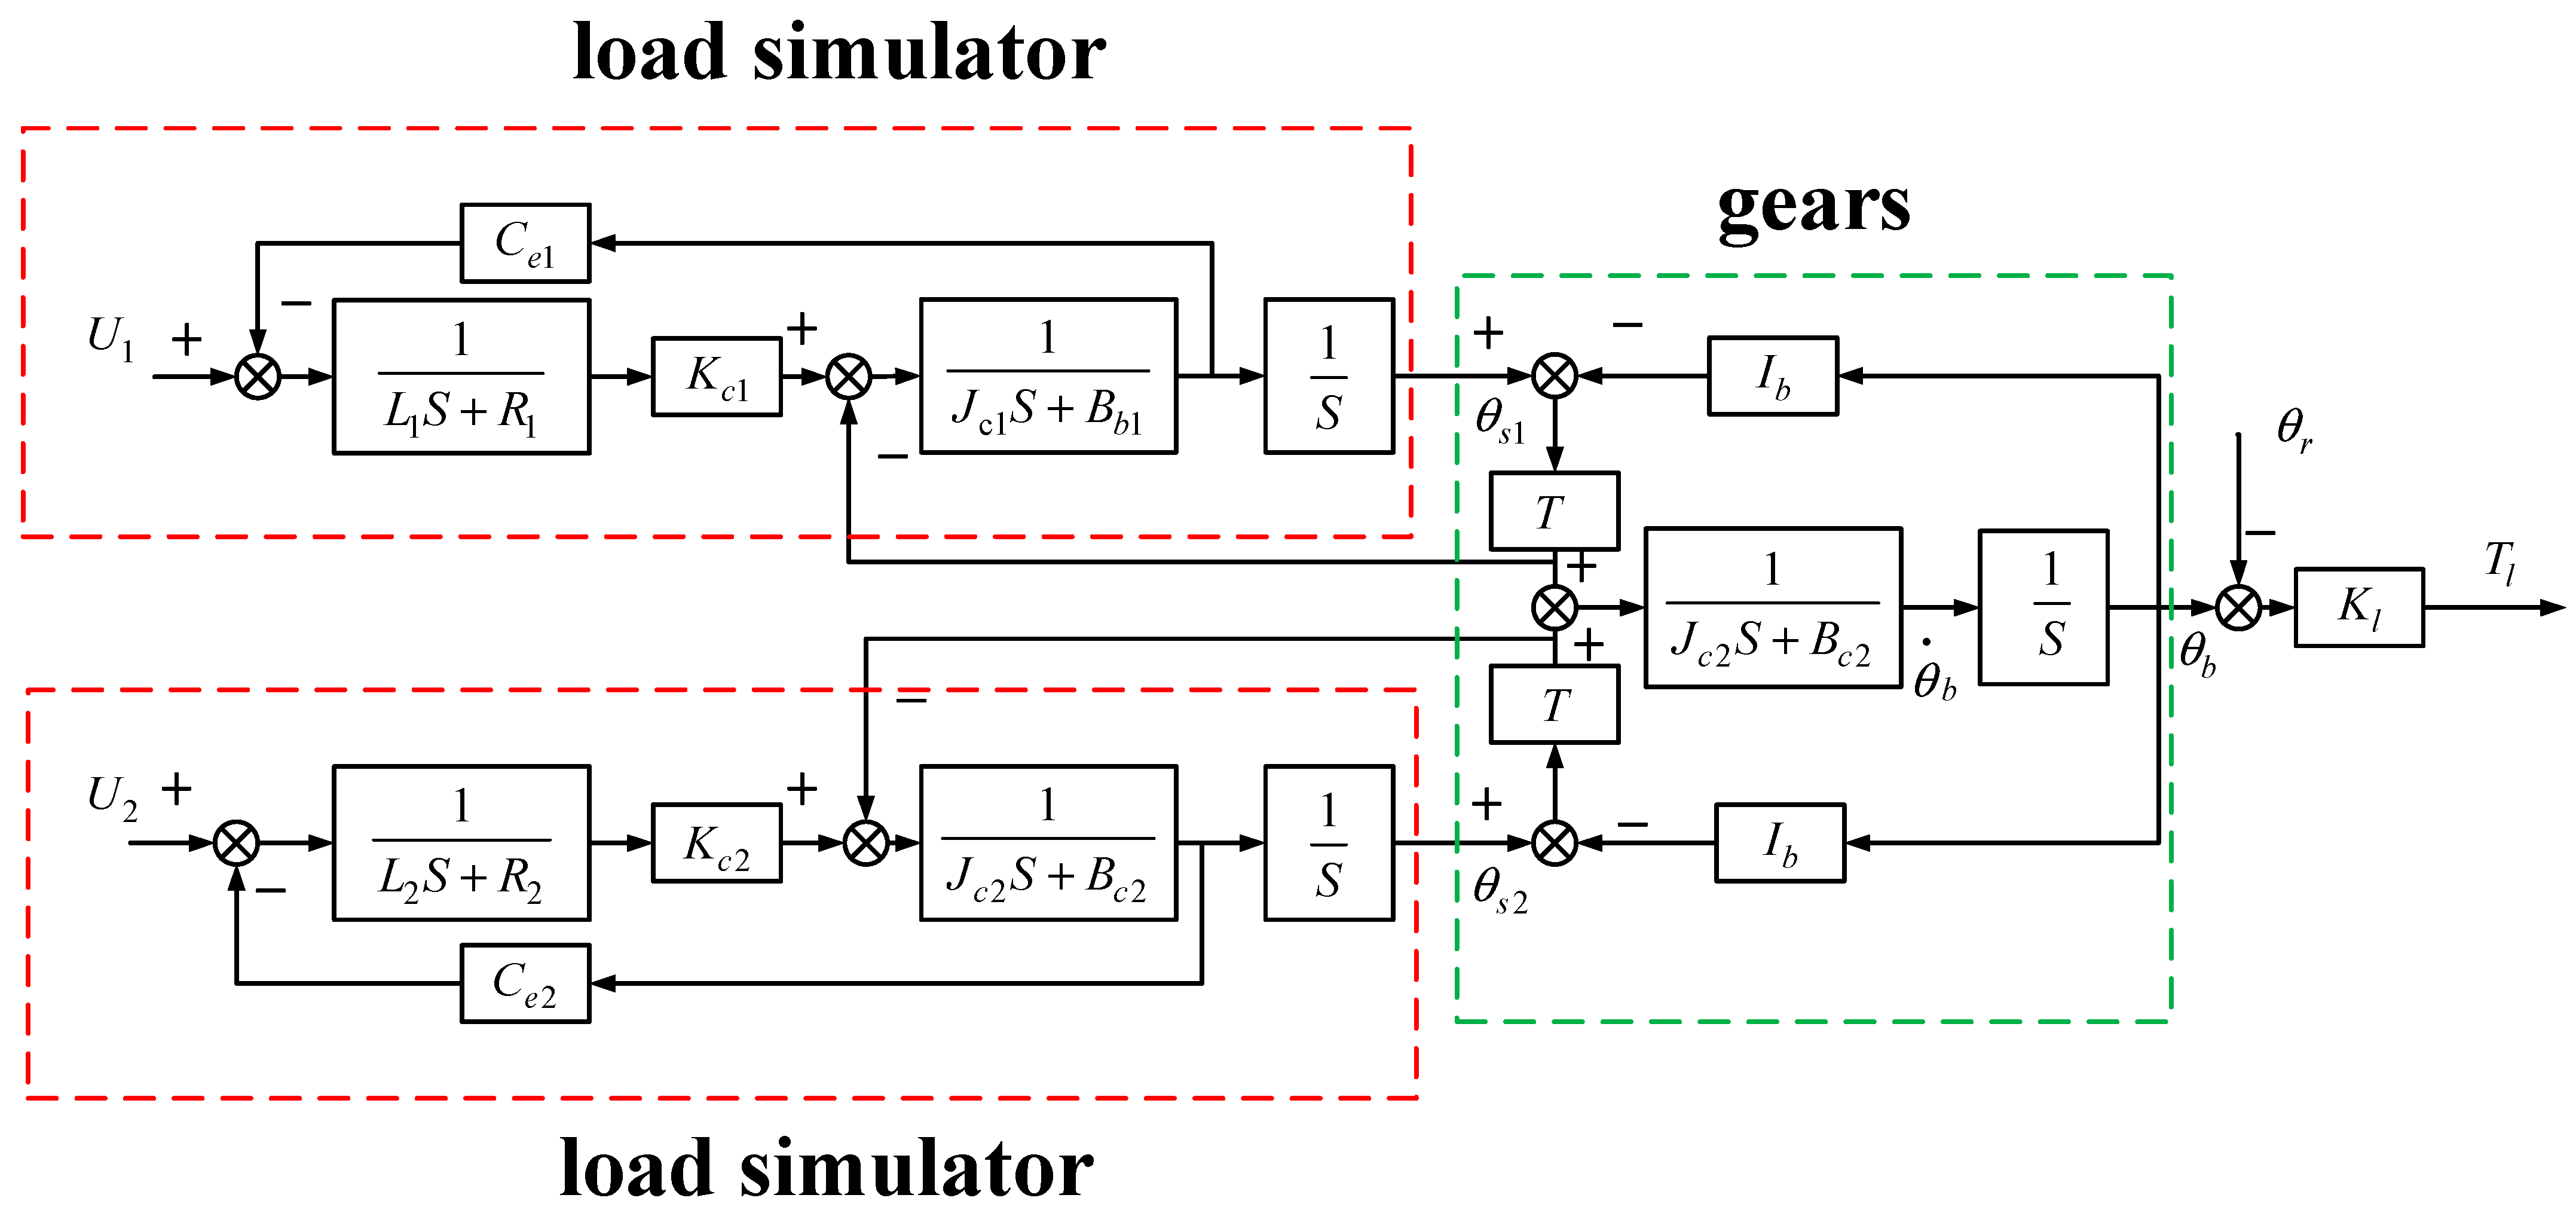
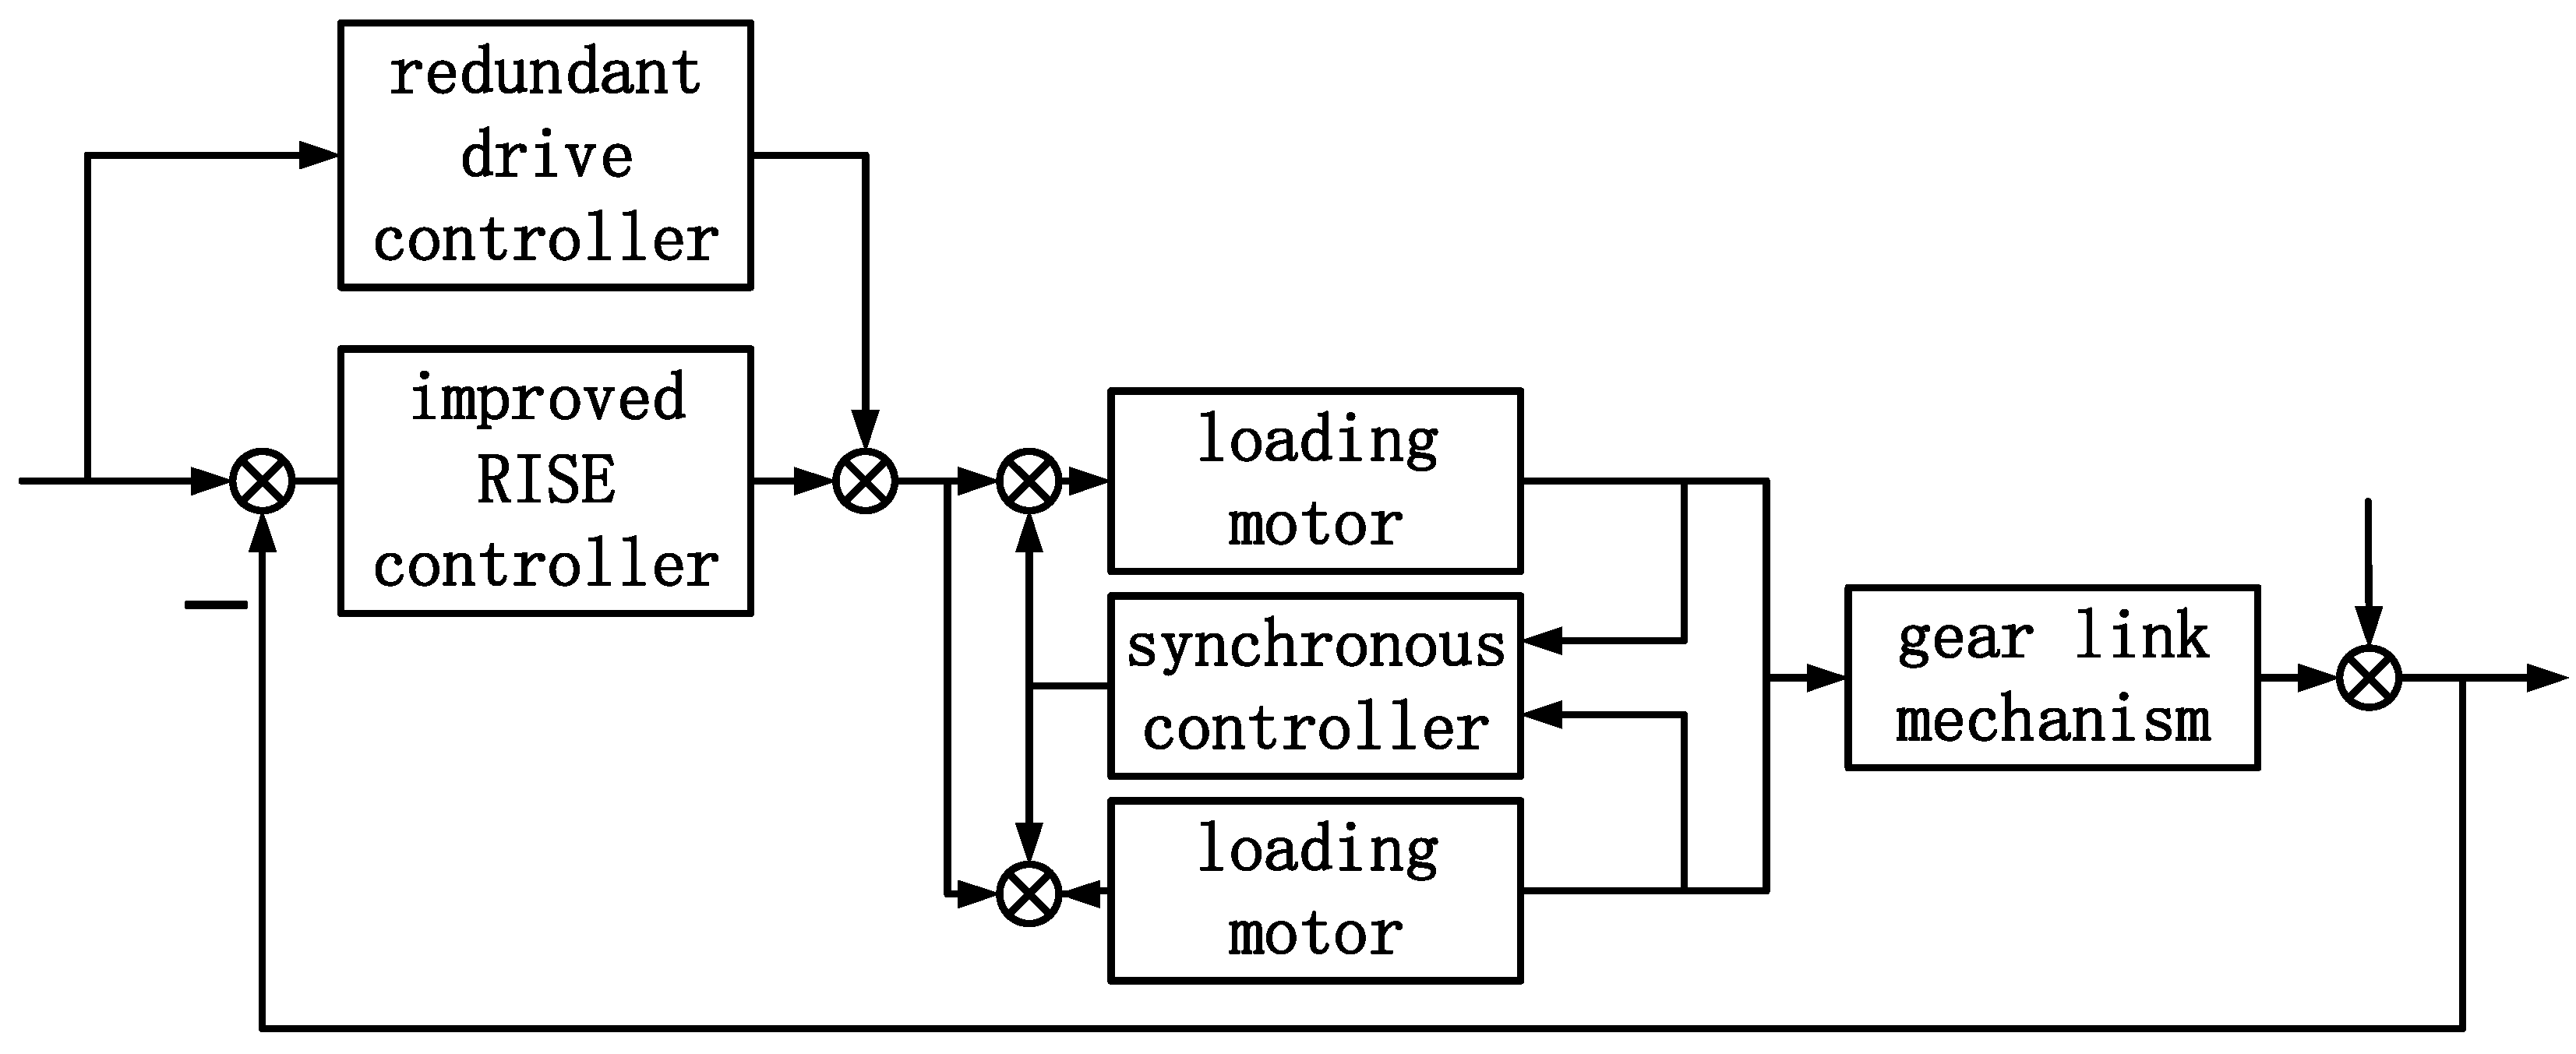
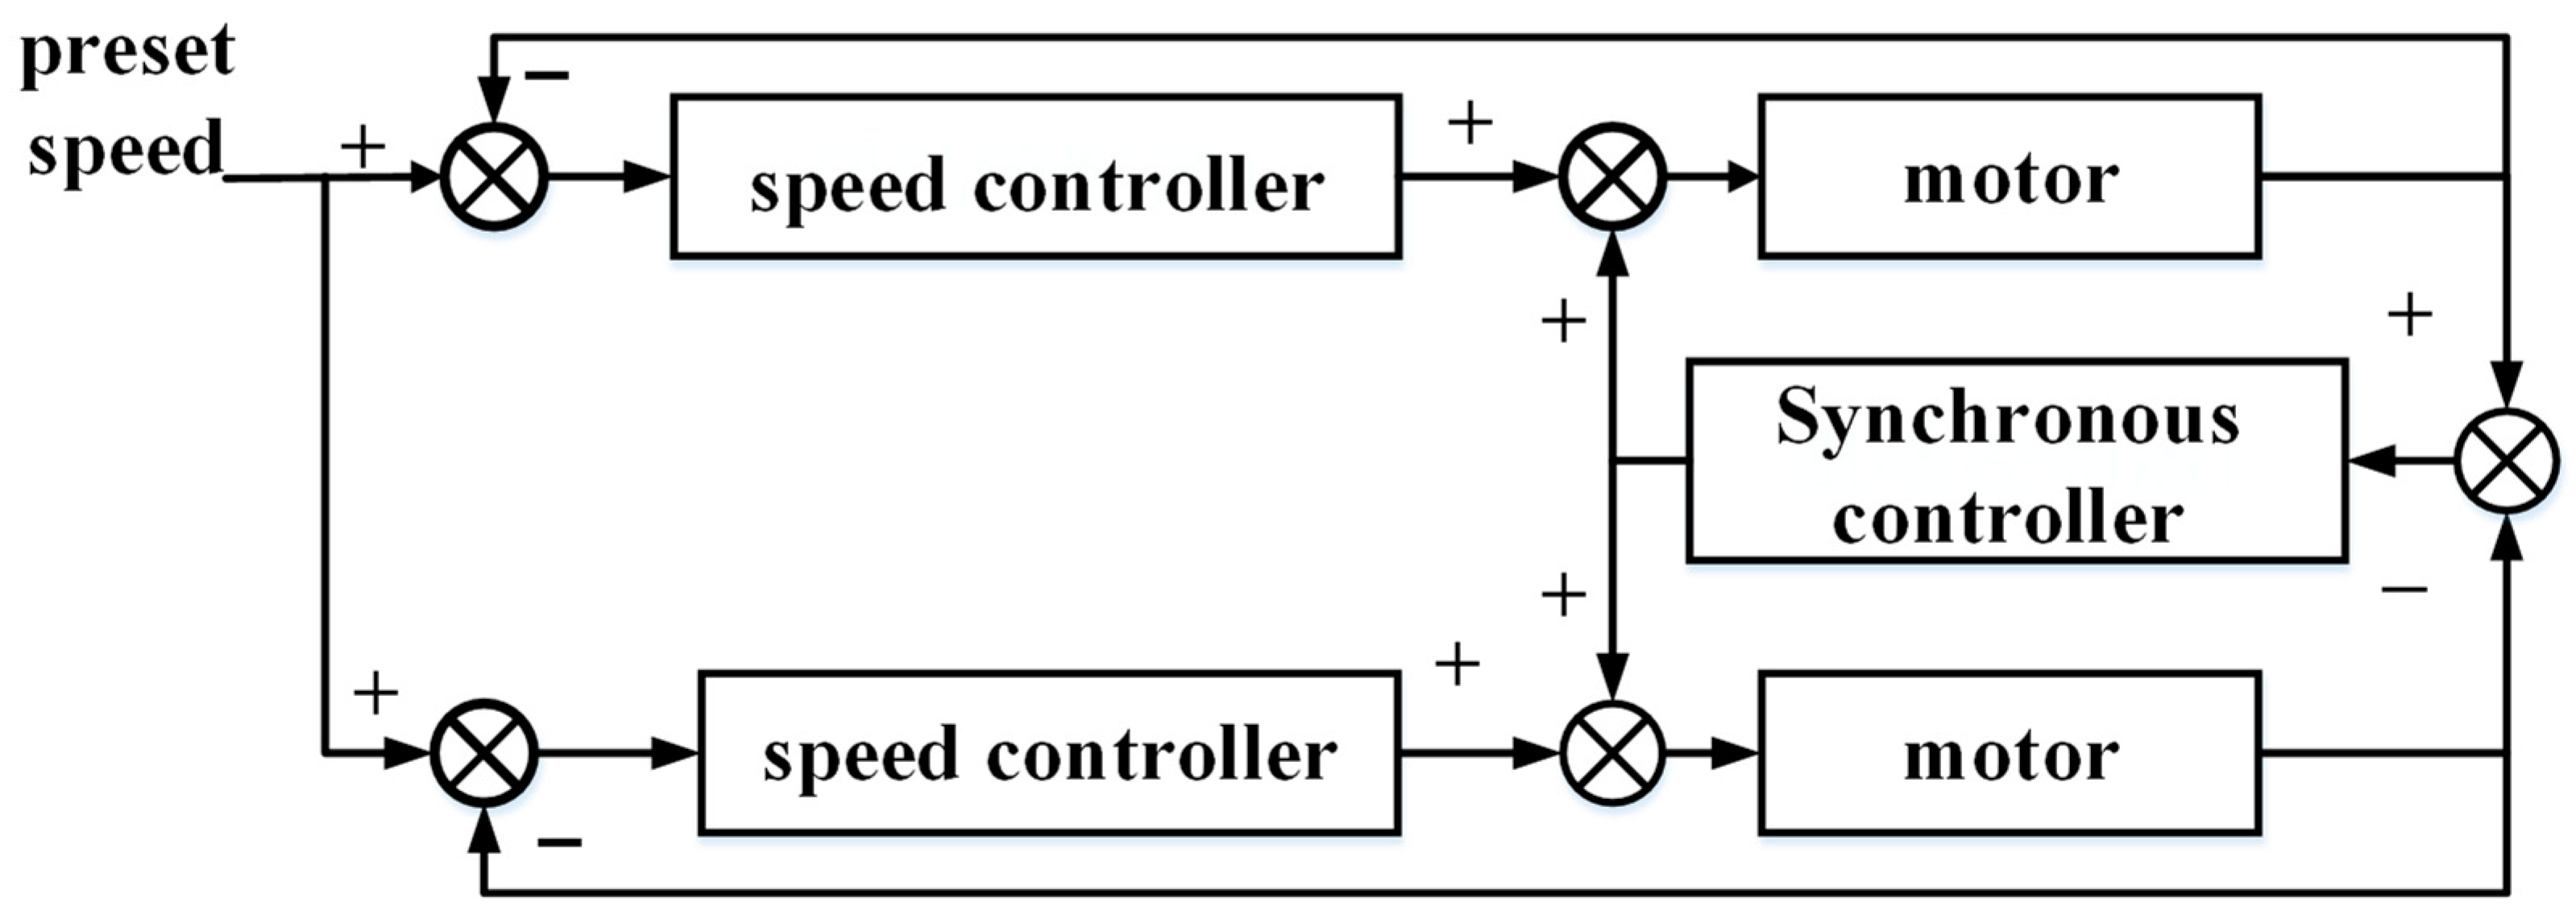
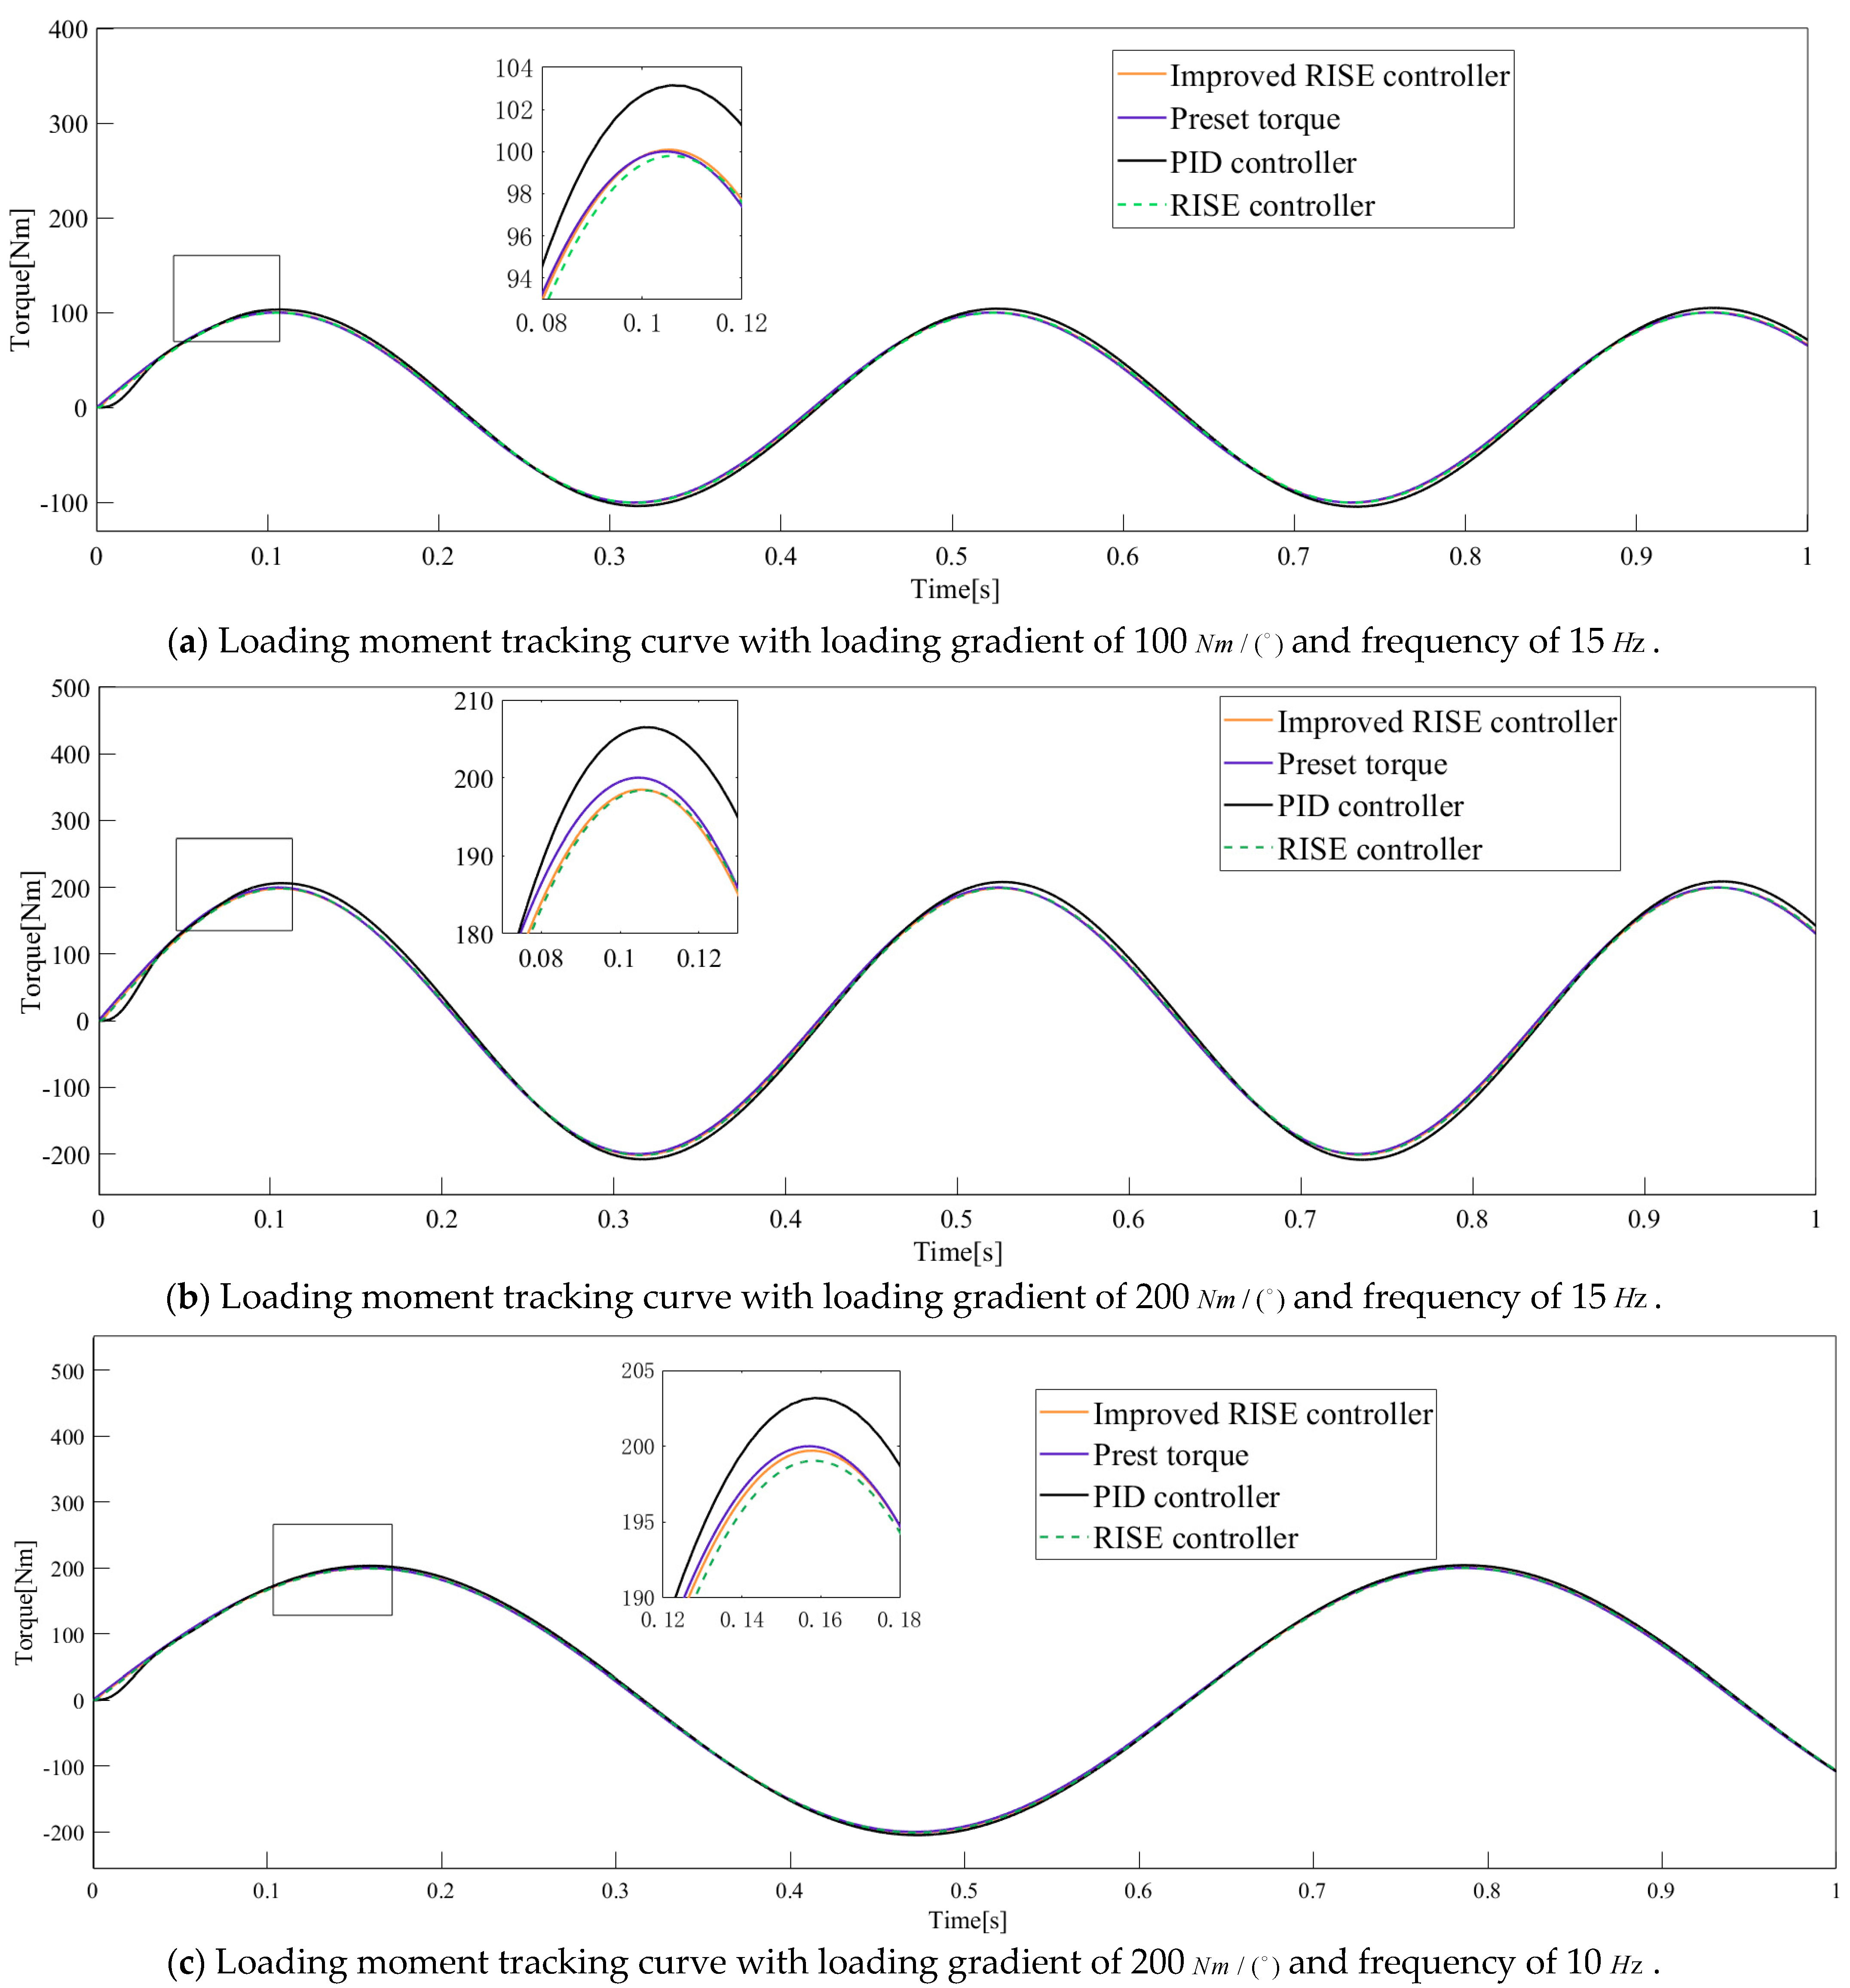
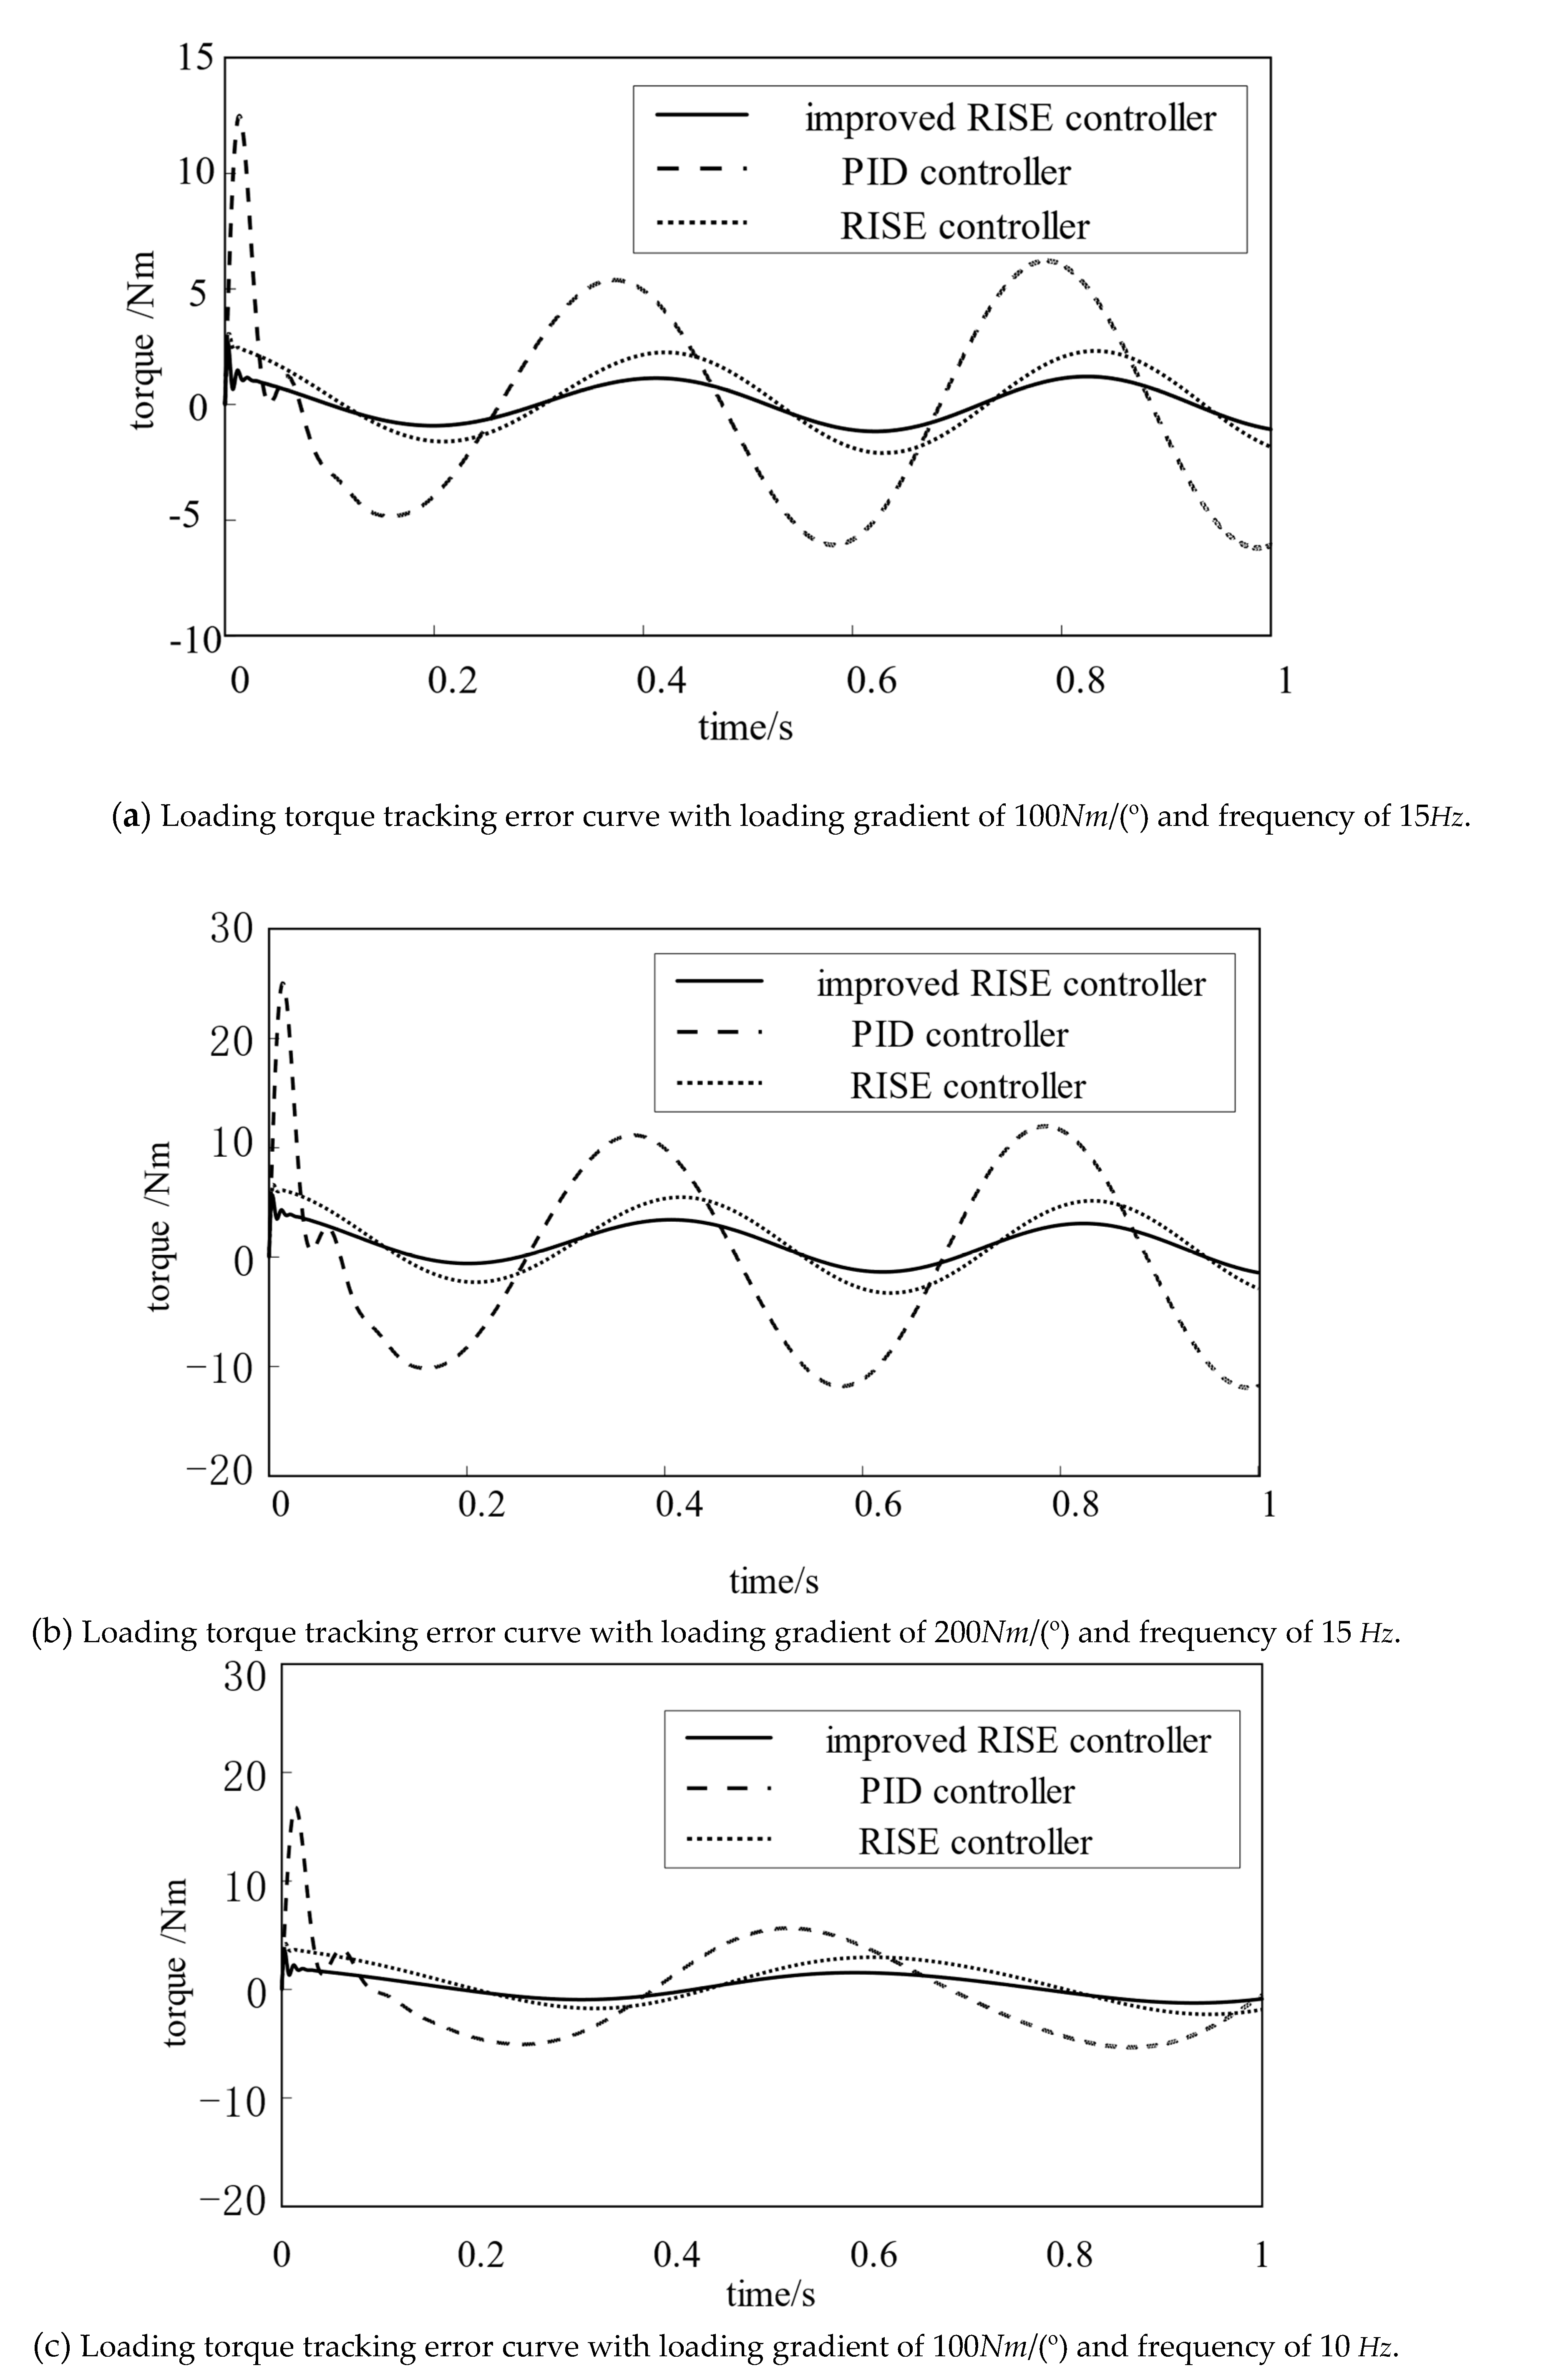
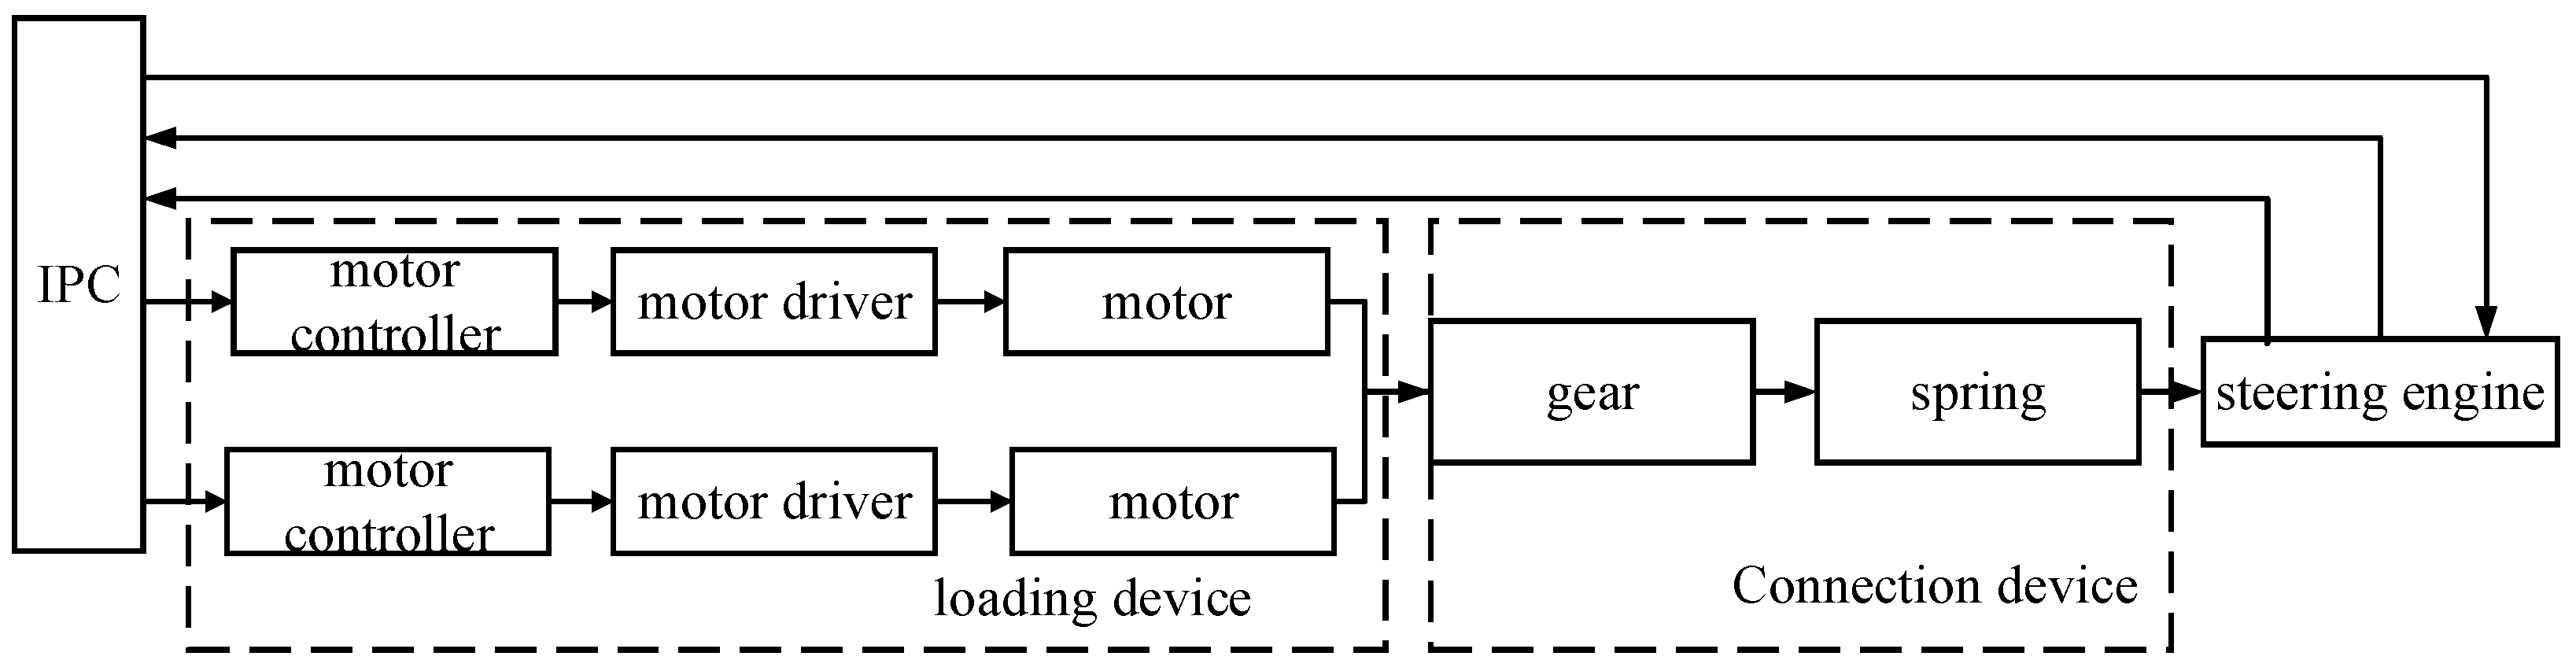
Aiming at the output torque error of a steering gear electric load simulator caused by excess torque and backlash interference, an electric load simulator based on double-motor loading is designed. The double-motor loading mode is adopted in the structure, the mathematical model is established, and the sources of excess torque and backlash interference are analyzed. In the control strategy, firstly, a torque controller is designed as a feedback controller based on the improved error symbol robust integral control method, and then a backlash interference compensator is designed as a feedforward controller based on the drive redundancy strategy. Finally, a dual motor speed synchronization controller is designed based on the improved cross coupling control method to ensure the stable operation of the torque controller and backlash compensator in the dual-motor system. The simulation results show that the compound control method can reduce the tracking error to 1.13%, 4.44% less than the PID control method. The tracking error is only 1.54% in the case of redundant torque, backlash, and different parameters of dual motors. The method proposed in this paper can still output loading torque with high accuracy.
Keywords: electric loading system; redundant torque; RISE; dual-motor electric loading system; redundant torque; RISE; dual-motor