Output Feedback Adaptive Tracking Control for Uncertain Strict-Feedback Nonlinear Systems with Full-State Constraints and Unknown Output Gain

Abstract
1. Introduction
- (1)
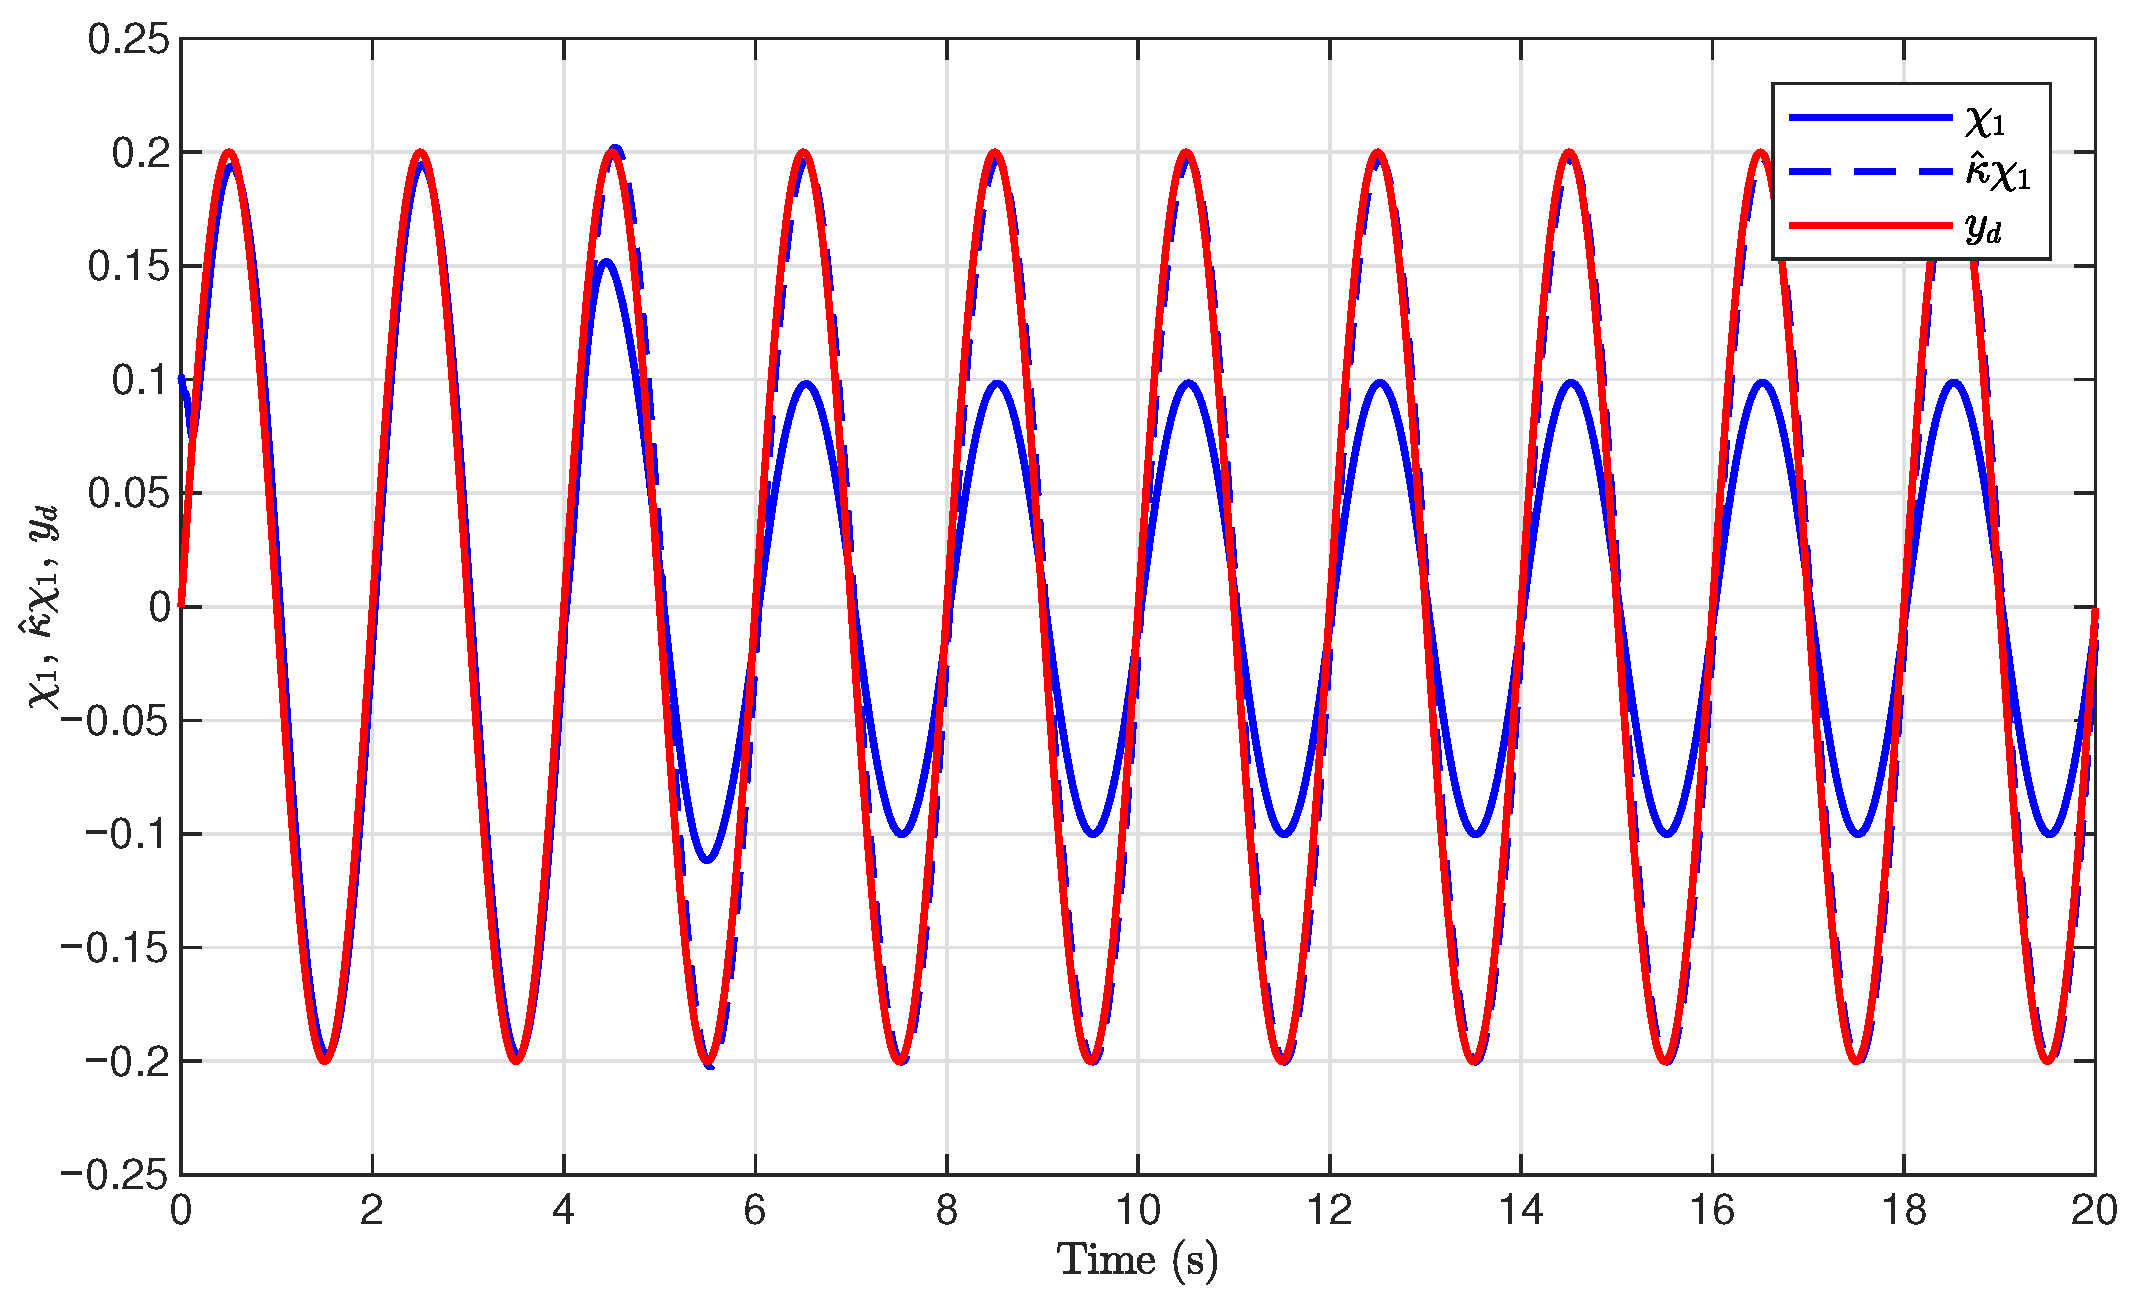
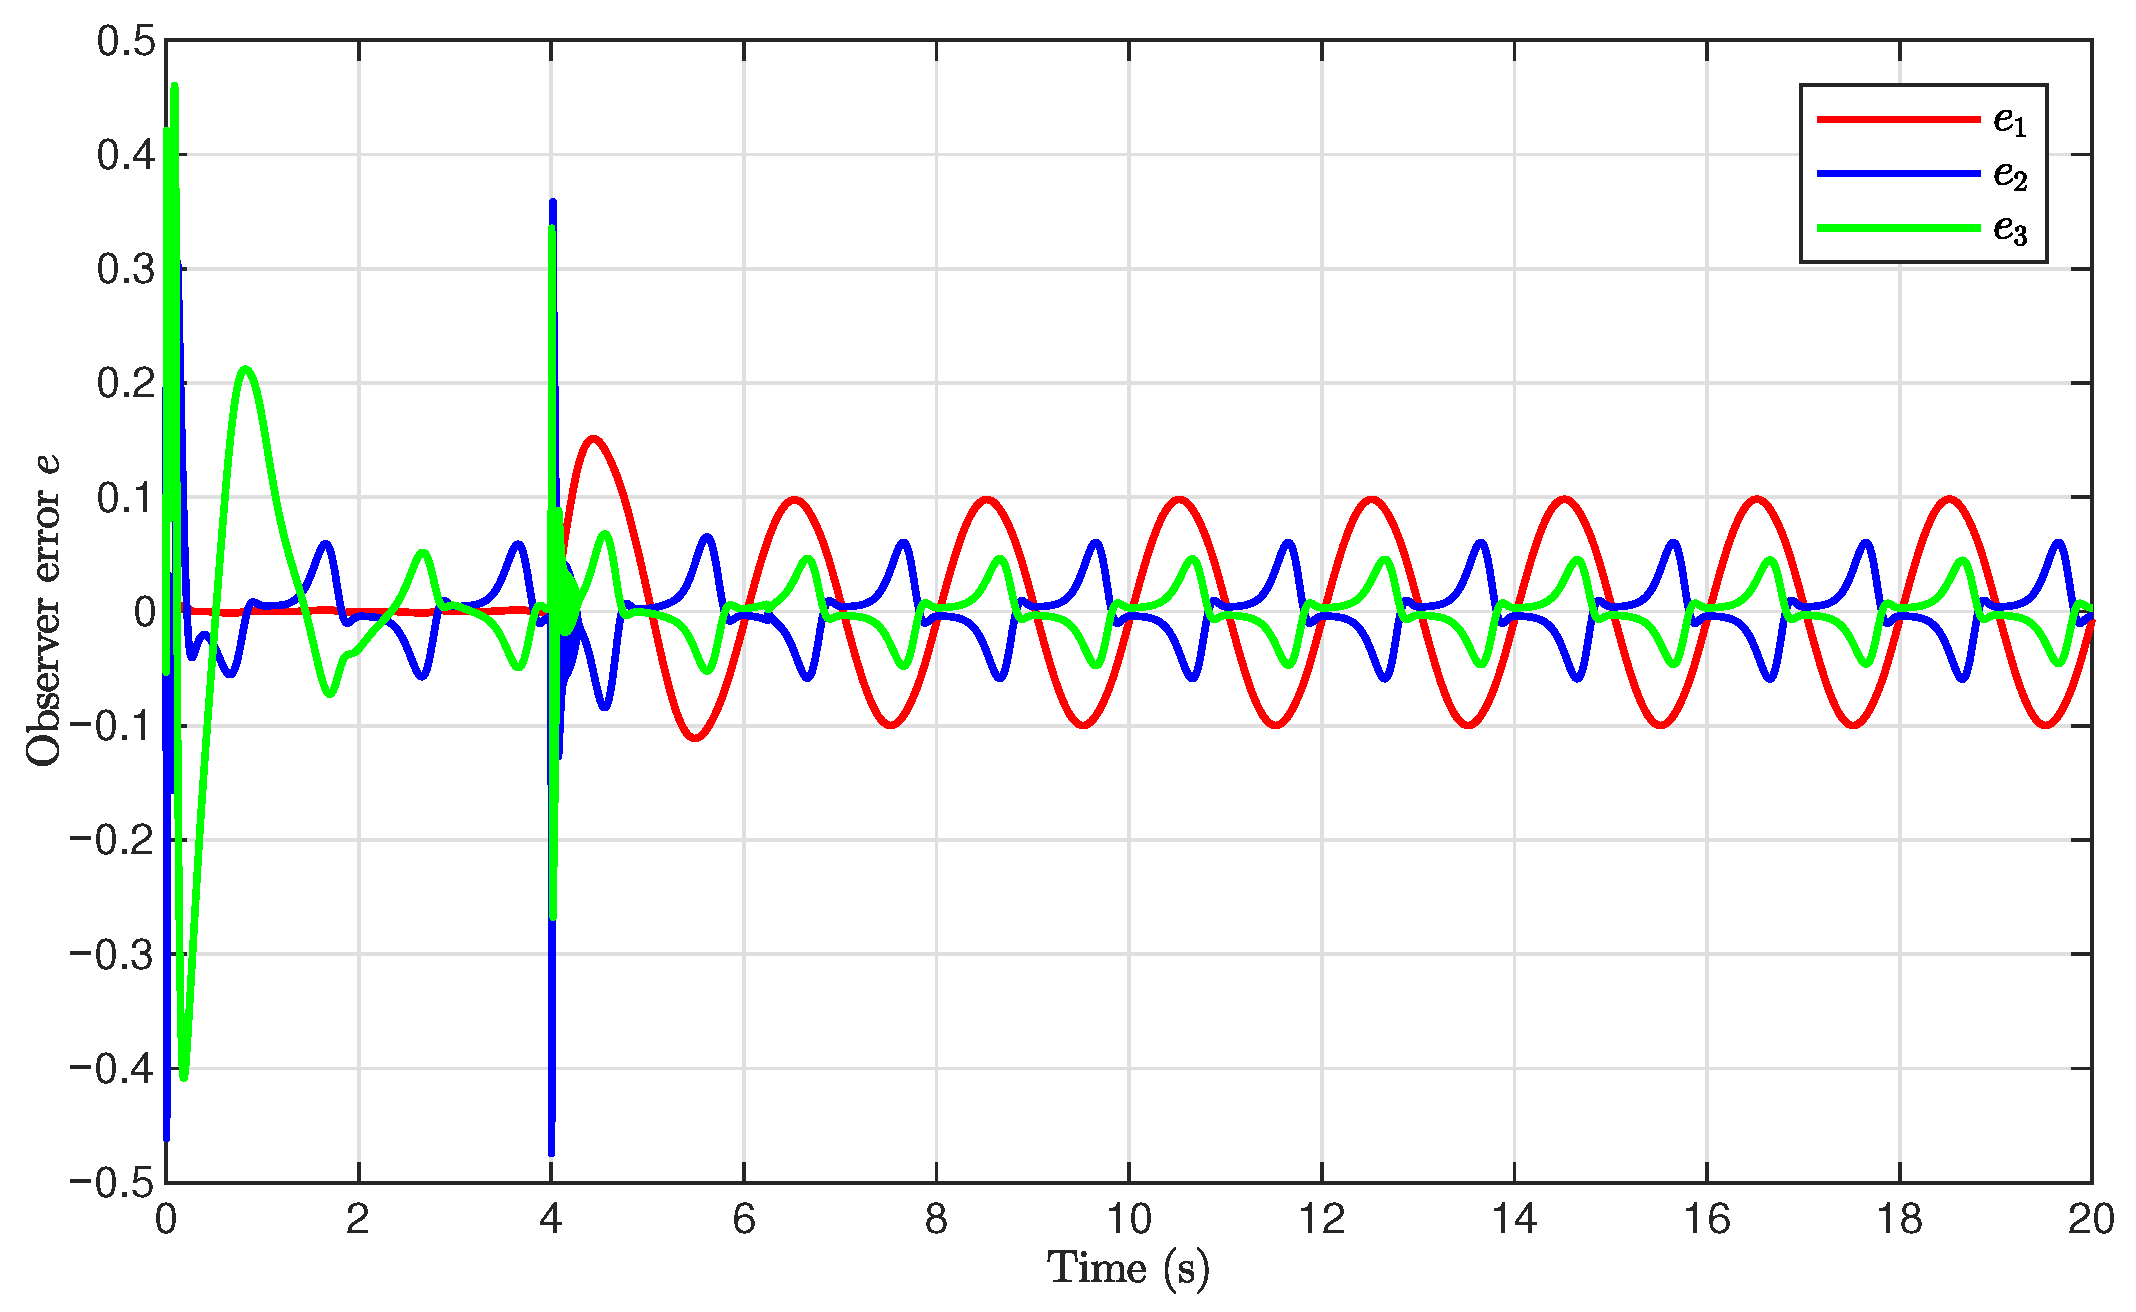
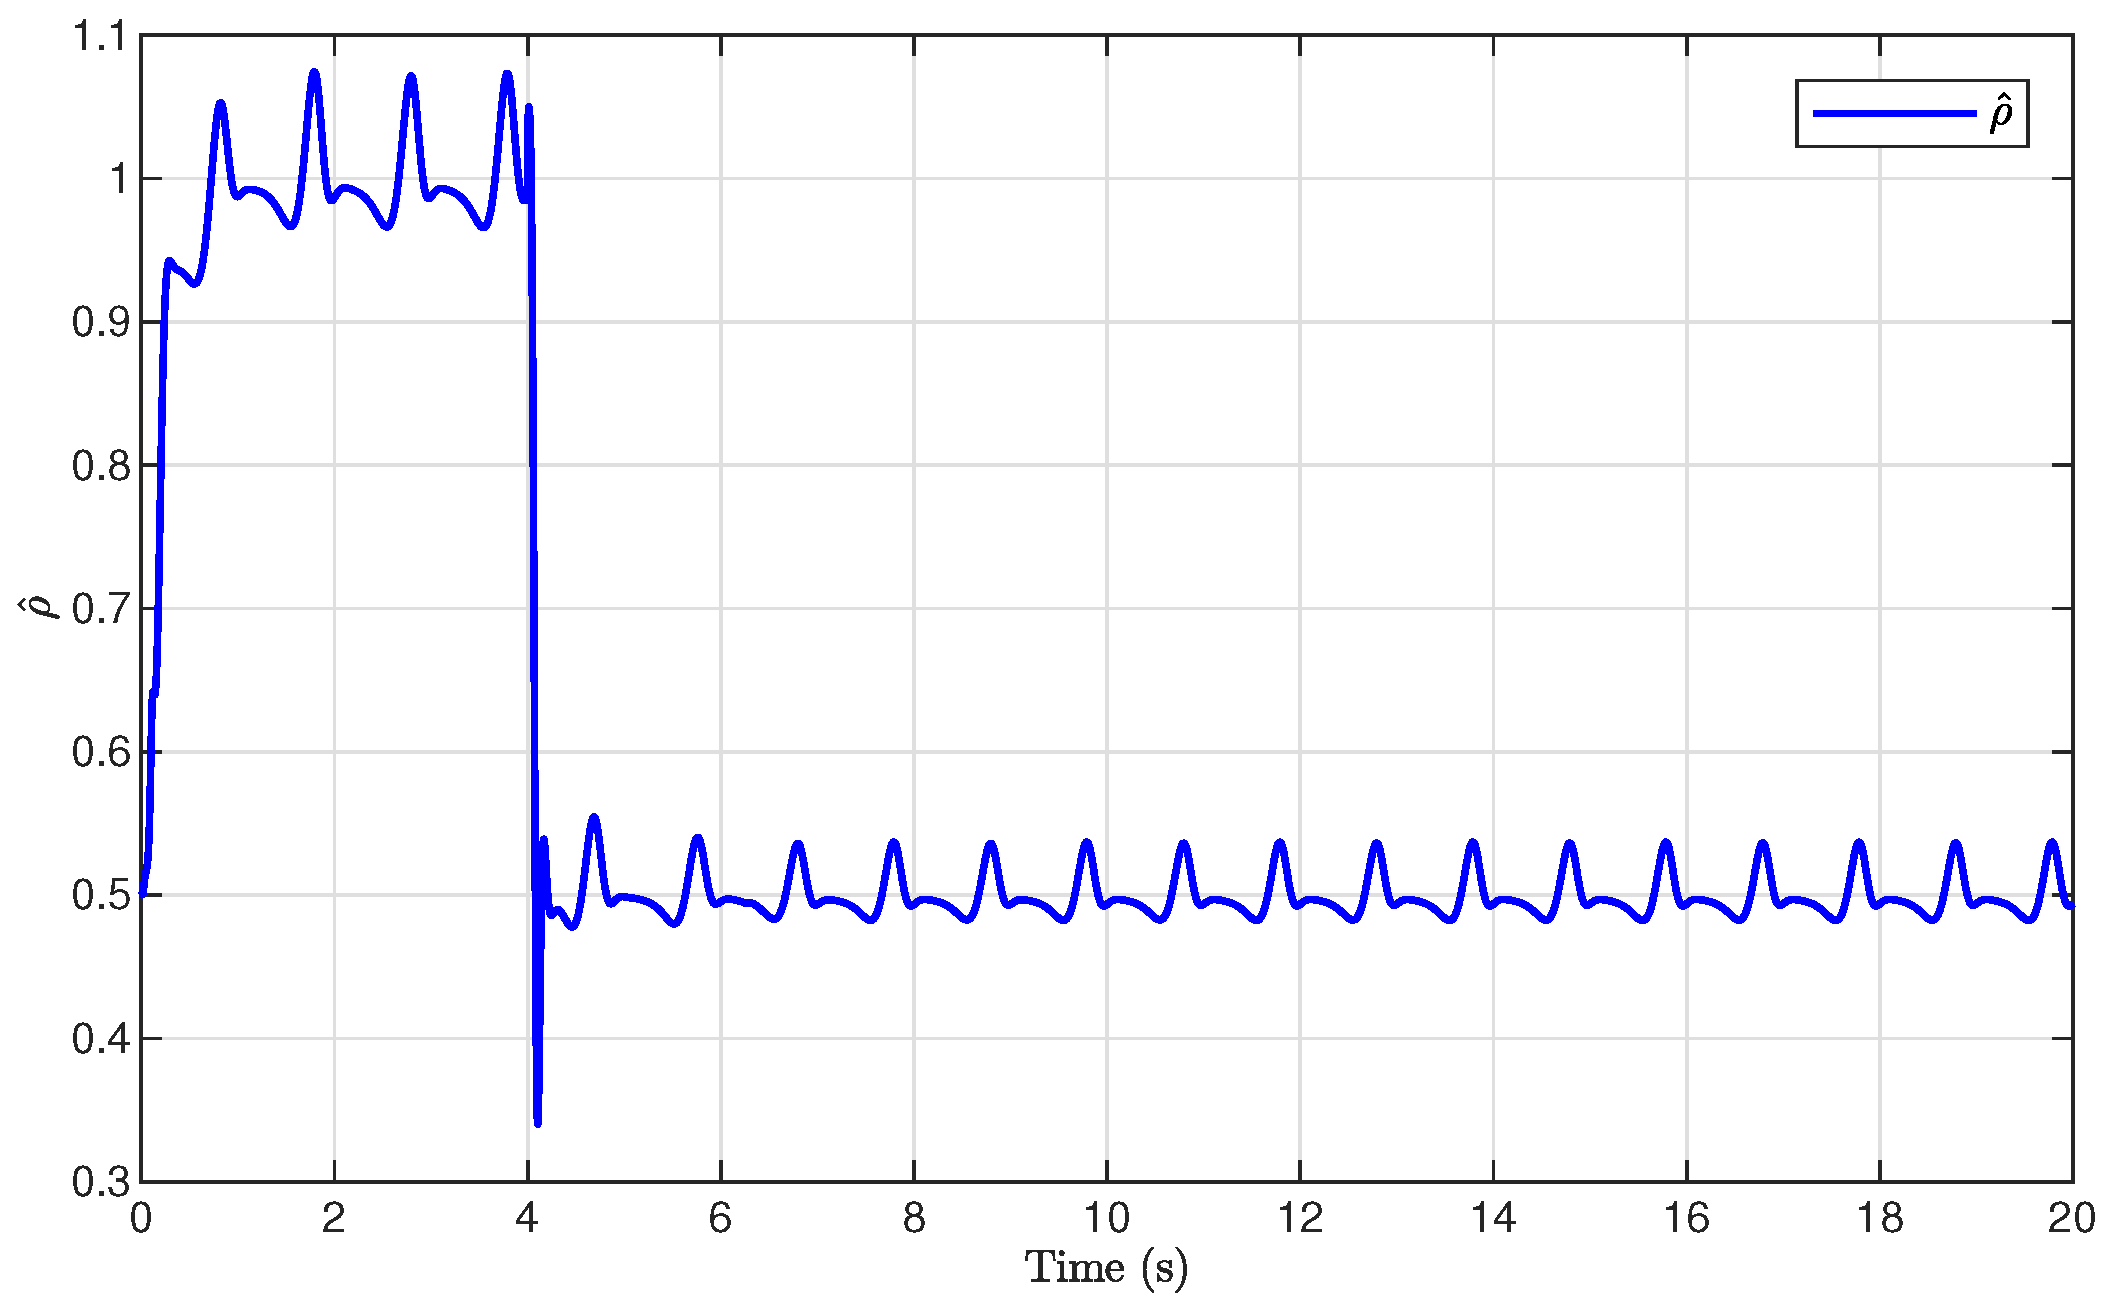
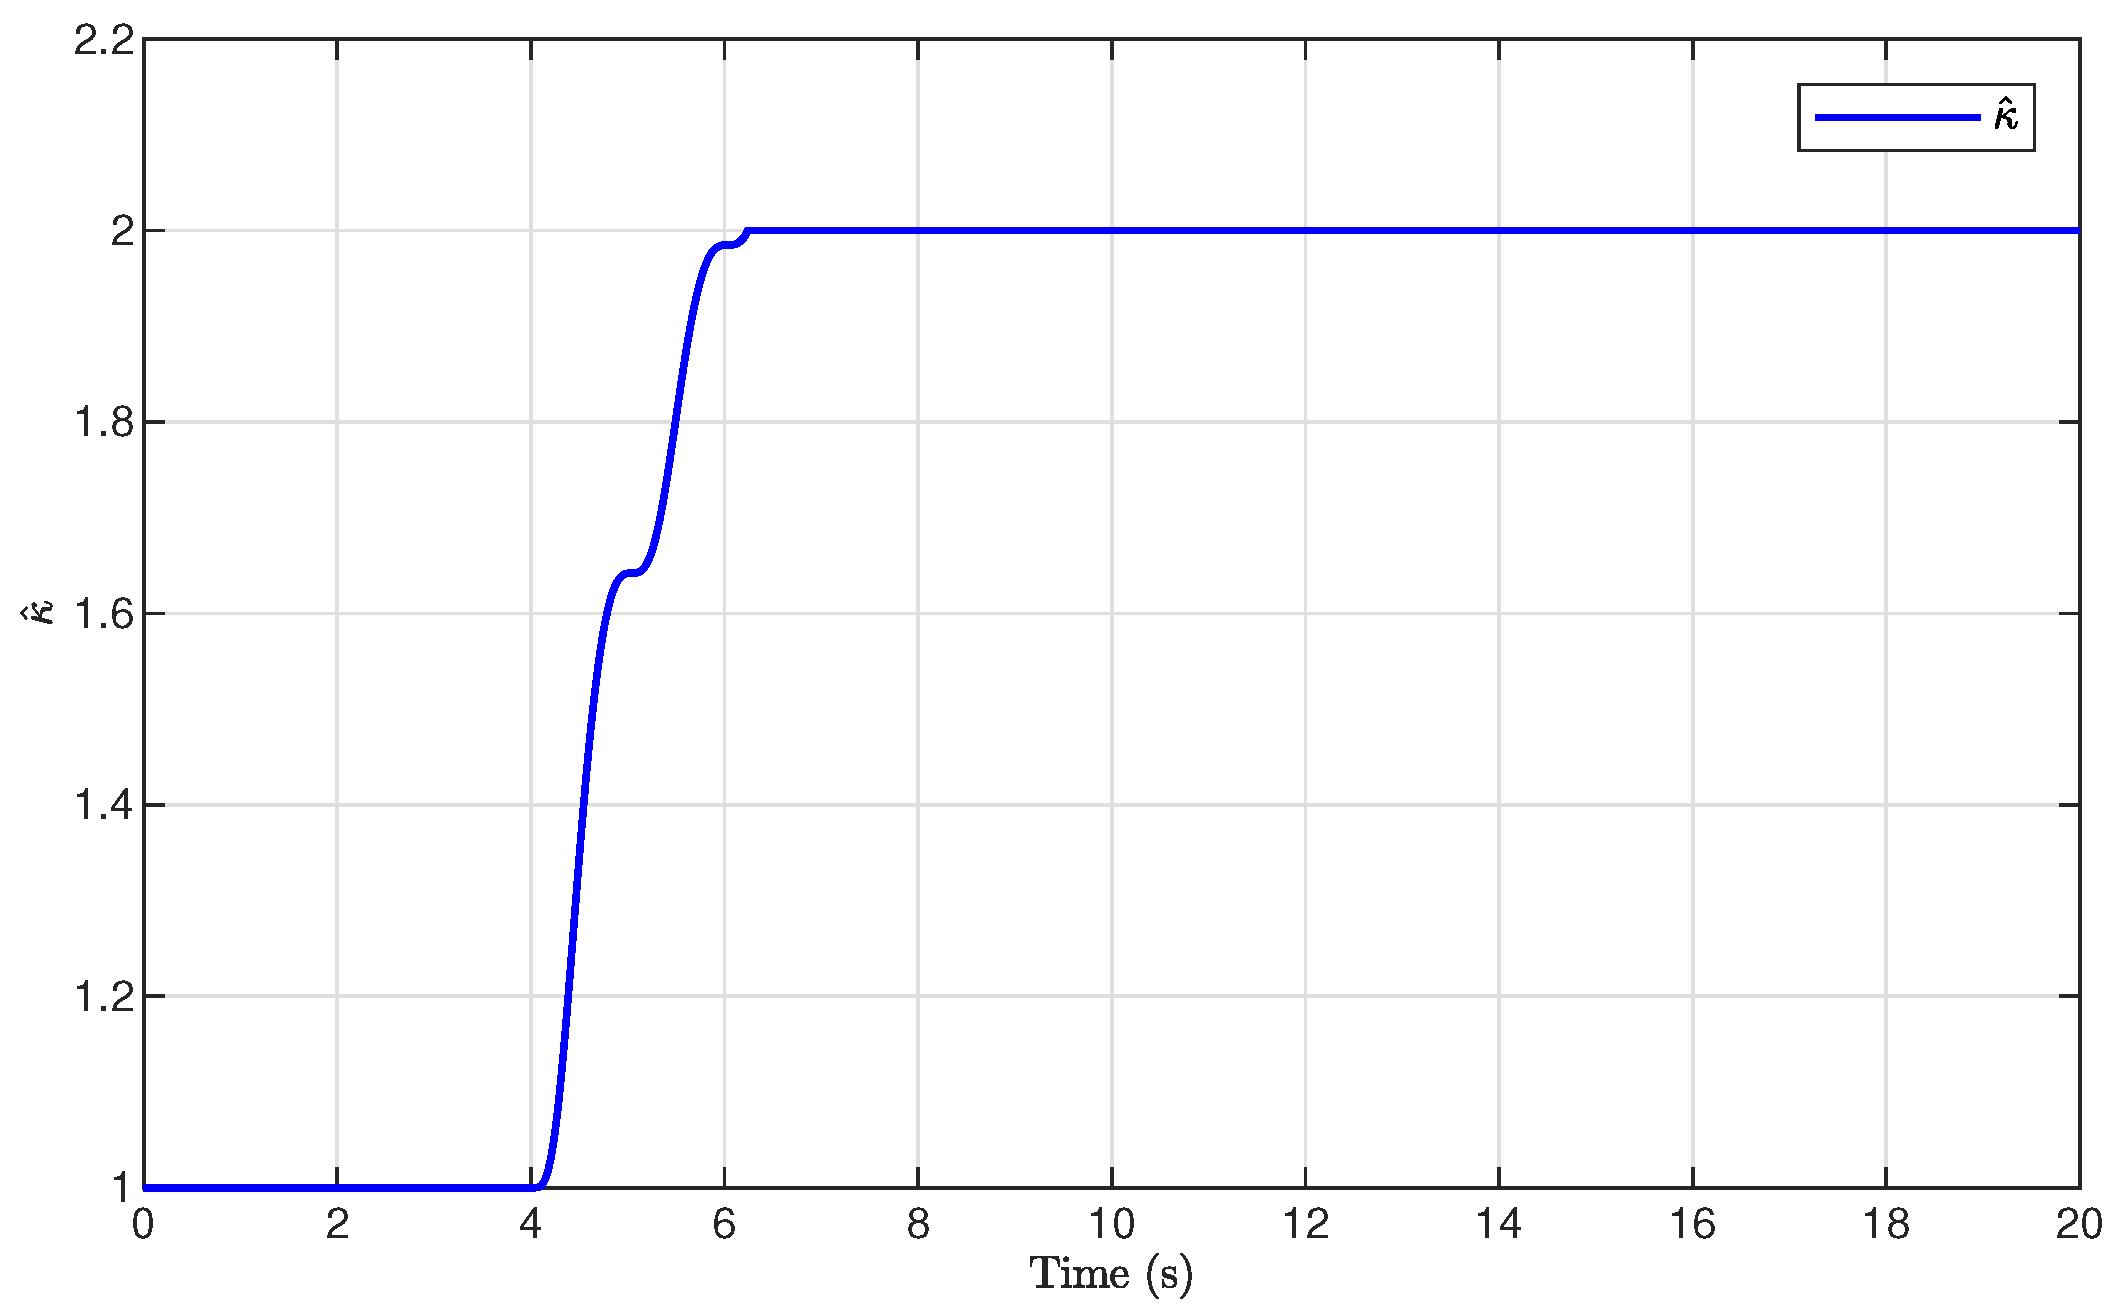
- An adaptive state observer is developed to reconstruct the unmeasured states under unknown output gain. By introducing a new error signal with an adaptive compensation coefficient into the observer-based backstepping design, together with the corresponding adaptive updating laws, the adverse effect of unknown output gain on tracking performance can be effectively reduced.
- (2)
- To handle asymmetric time-varying full-state constraints, a control design combining the universal transformed function with a novel coordinate transformation is proposed. The developed method guarantees that all system states remain within the prescribed asymmetric constraint boundaries throughout the entire operation process, without requiring the strict feasibility conditions encountered in conventional BLF-based approaches.
- (3)
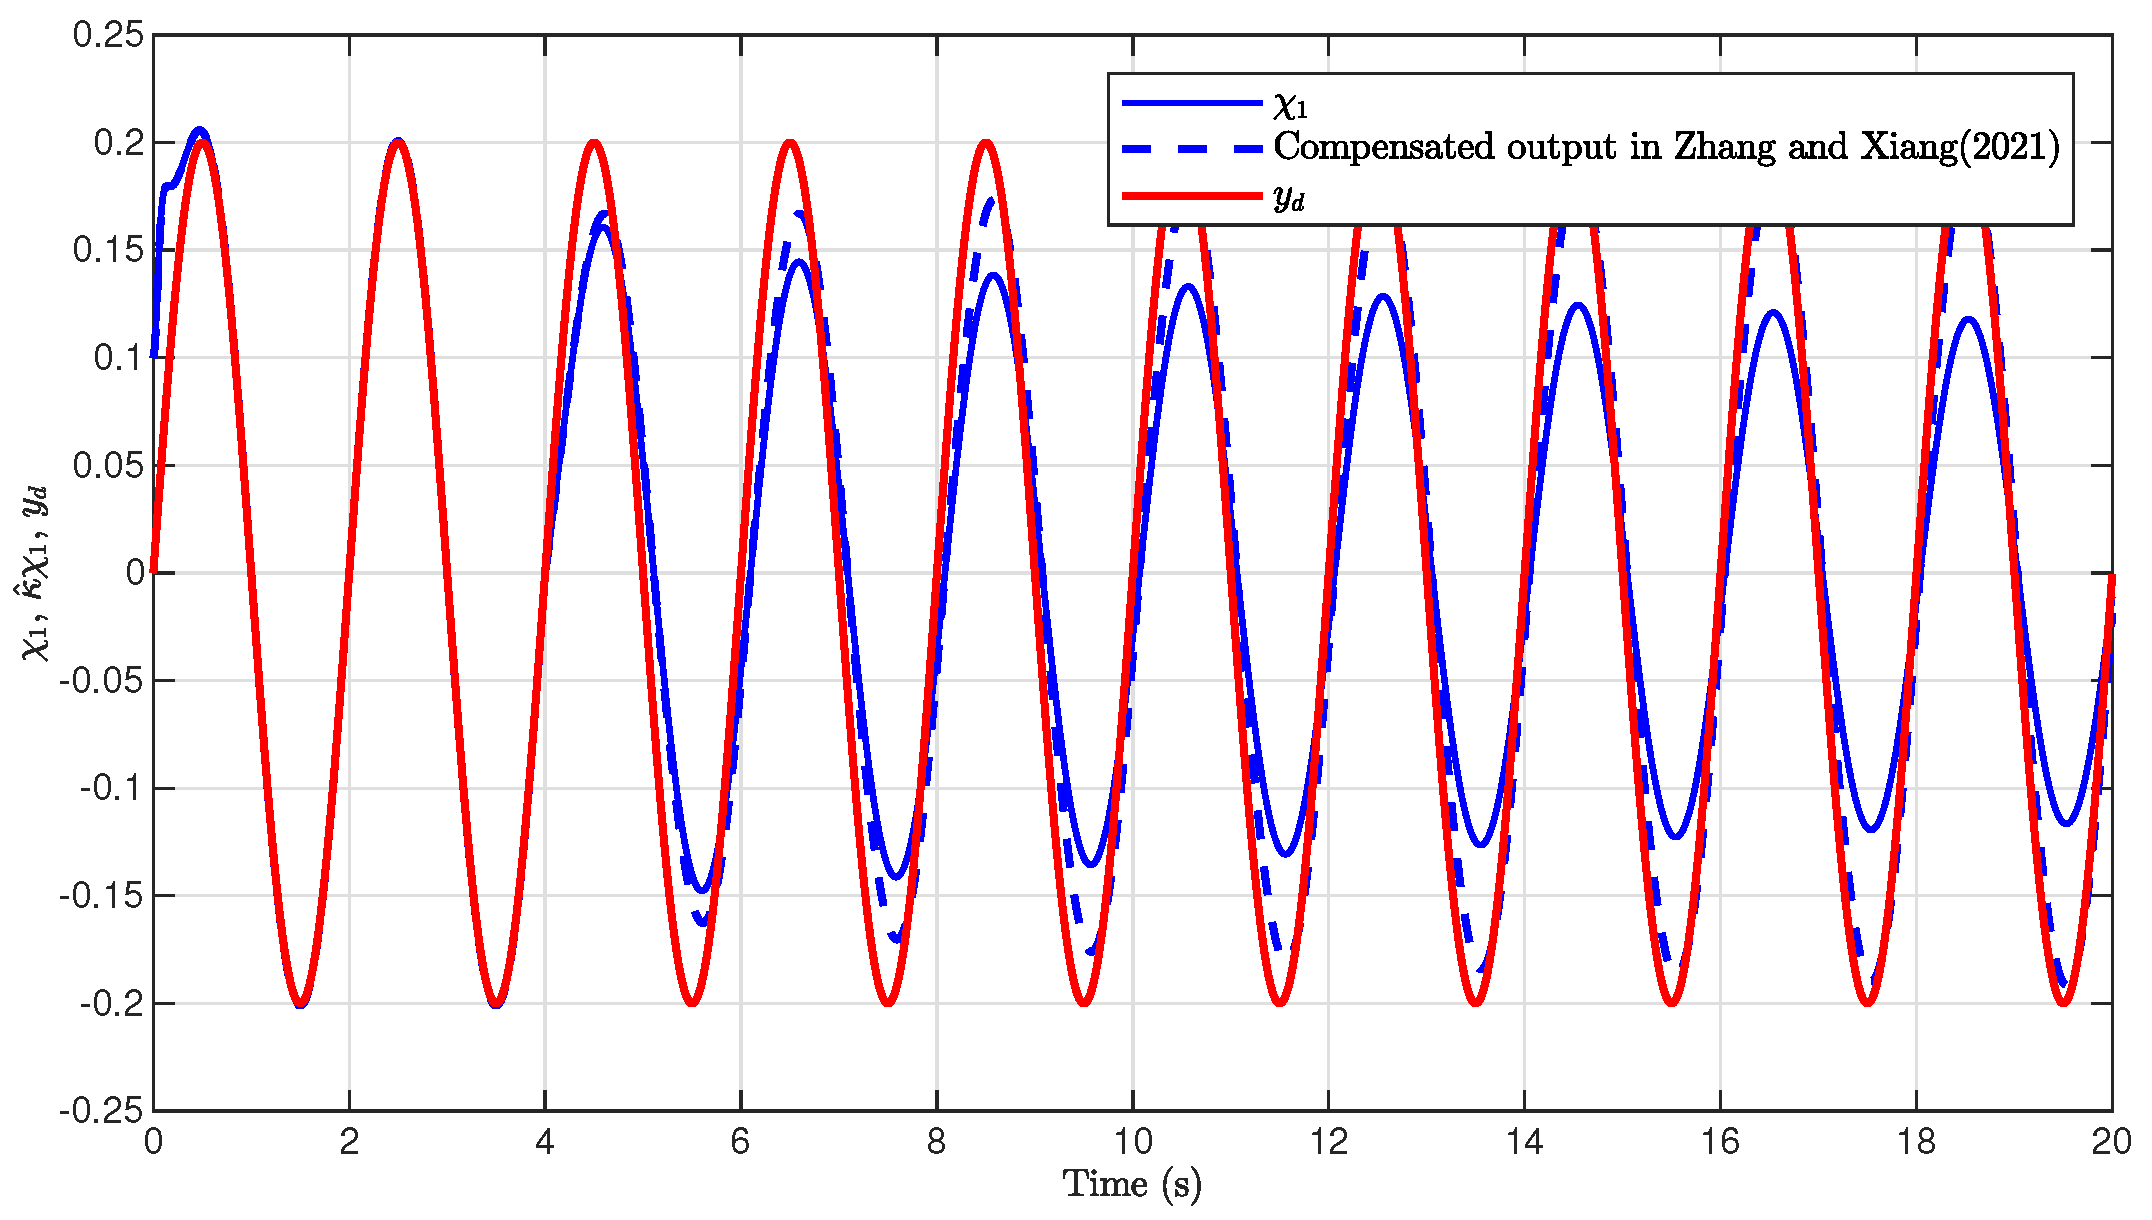
- By integrating adaptive state estimation and constraint-handling mechanisms into a single design, the proposed approach addresses the challenge of guaranteeing constraint satisfaction when the available output information is affected by unknown gain. Different from the compensation-based control methods in [16,17], where asymmetric full-state constraints are not explicitly addressed, the proposed method further incorporates a constraint-handling mechanism into the output-feedback control design. In addition, compared with the constrained control methods in [26], where adaptive compensation for unknown output gain was not considered, an adaptive compensation mechanism is incorporated in the proposed design to effectively reduce the influence of unknown output gain while ensuring constraint satisfaction.
2. Problem Statement and Preliminaries
2.1. Problem Statement
- (1)
- The closed-loop signals in the system are globally uniformly ultimately bounded.
- (2)
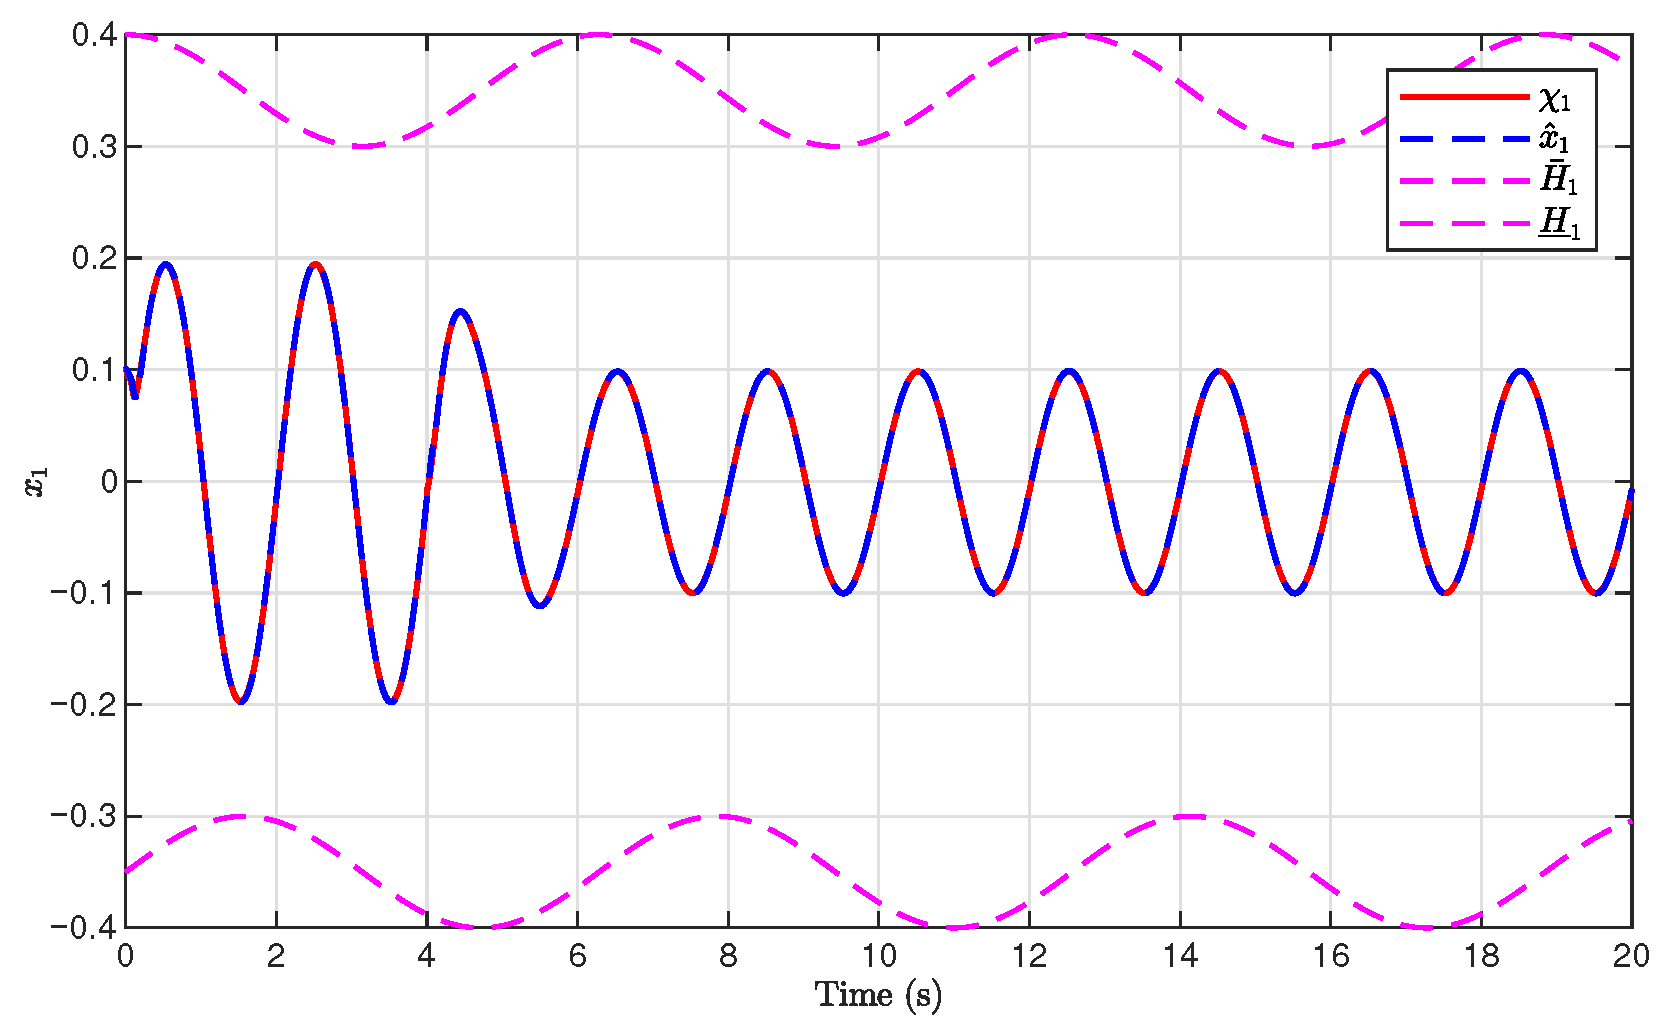
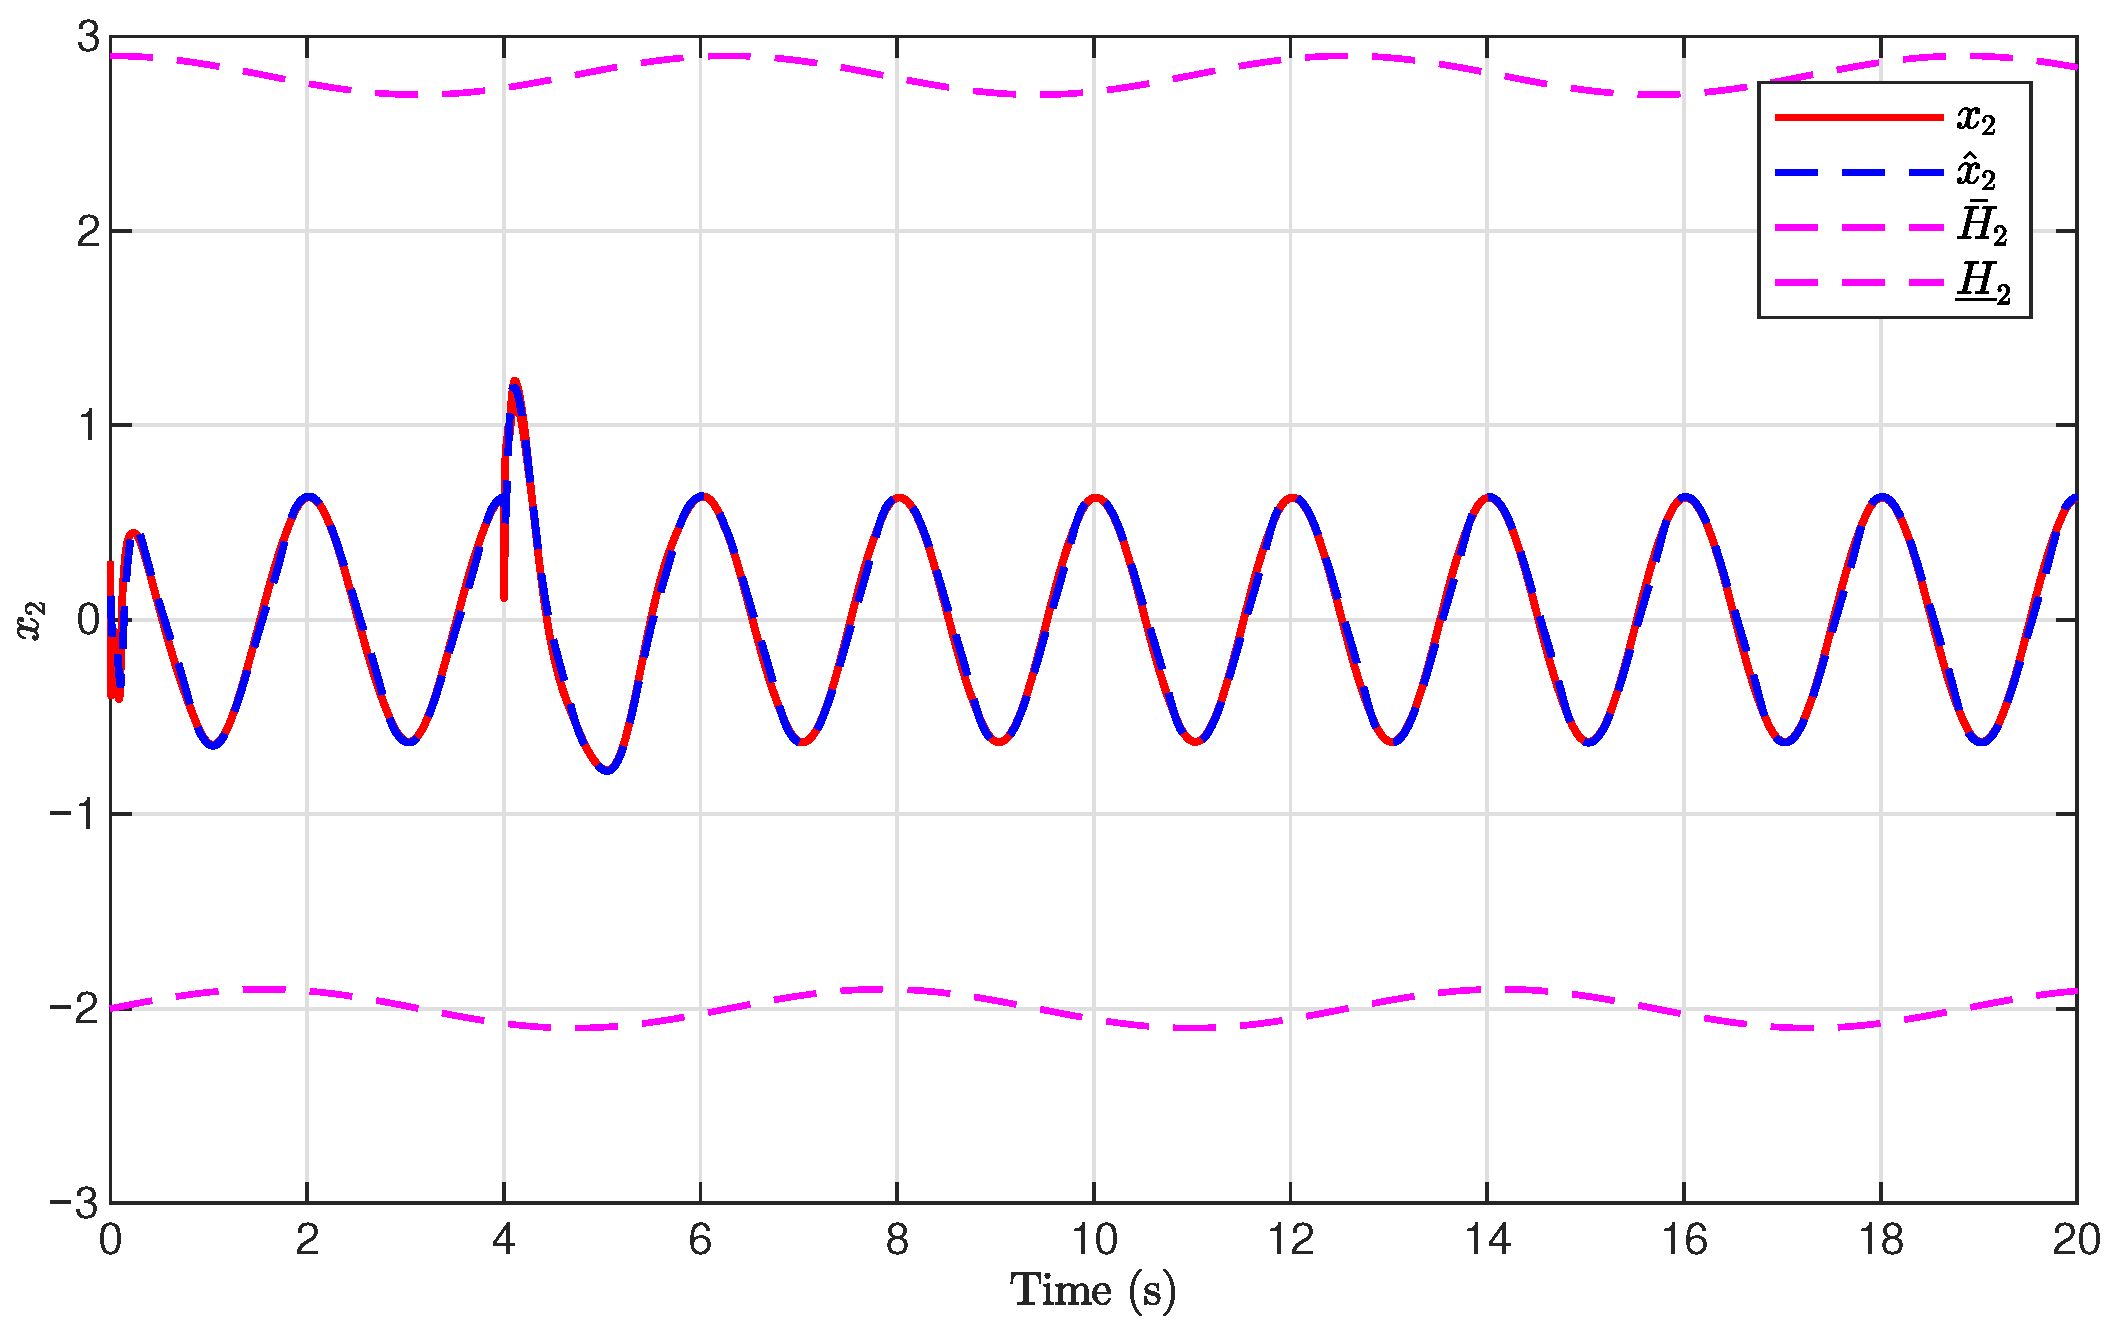
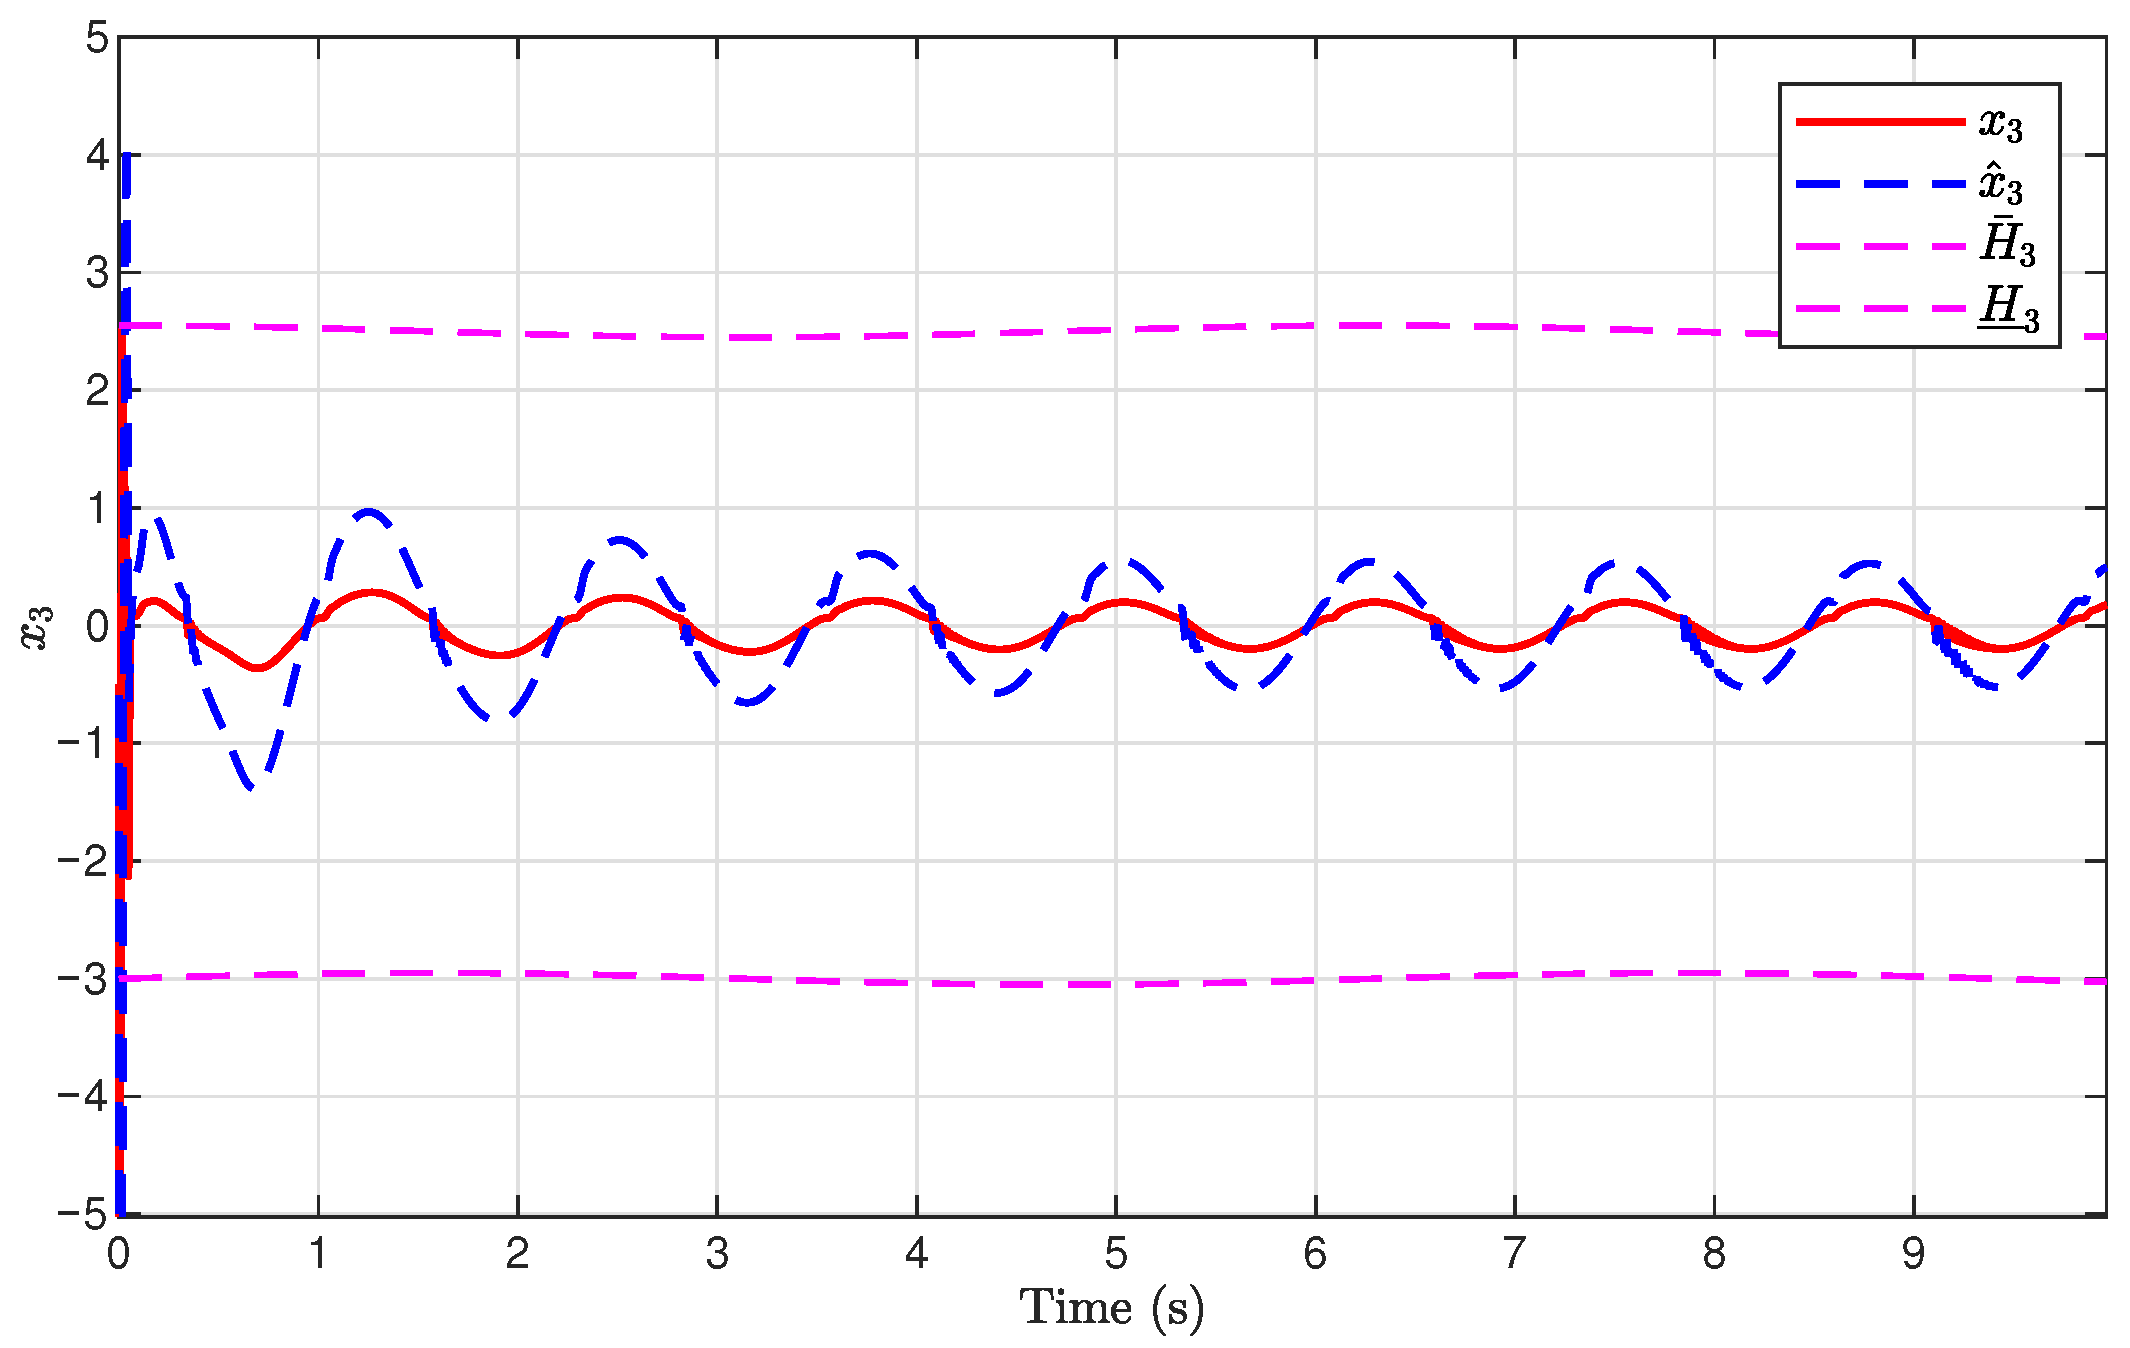
- The system output y is required to follow the reference trajectory while ensuring that all system states remain within the time-varying asymmetric boundaries:In this formulation, and are positive and twice differentiable constraint functions, respectively.
2.2. Preliminaries
3. Output-Feedback Adaptive Tracking Control Design
3.1. Universal Transformed Functions
3.2. Design of Adaptive State Observer
3.3. Design of Backstepping Adaptive Controller
3.4. Stability Analysis
- (1)
- All signals in the closed-loop system remain uniformly bounded;
- (2)
- The system states always evolve within the time-varying asymmetric constraint bounds.
4. Simulation
5. Conclusions
Author Contributions
Funding
Data Availability Statement
Conflicts of Interest
References
- Lu, K.; Yu, H.; Liu, Z.; Han, S.; Yang, J. Inverse Optimal Adaptive Control of Canonical Nonlinear Systems With Dynamic Uncertainties and Its Application to Industrial Robots. IEEE Trans. Ind. Inform. 2024, 20, 5318–5327. [Google Scholar] [CrossRef] [Scilit]
- Zhou, Z.; Zhang, S.; Xu, Z.; Peng, Y.; Jin, X. High-Quality Positioning Strategy for Biaxial Contour Machining System With Nonlinear Model Predictive Control. IEEE J. Emerg. Sel. Top. Power Electron. 2023, 11, 4355–4367. [Google Scholar] [CrossRef] [Scilit]
- Zheng, X.; Wen, H.; Yang, X.; Yu, X.; Rodriguez-Andina, J.J. Adaptive Neural Zeta-Backstepping With Predefined Damping Ratio: Application to DC Motors. IEEE Trans. Cybern. 2025, 55, 1701–1705. [Google Scholar] [CrossRef] [Scilit]
- Zhang, J.; Niu, B.; Wang, D.; Wang, H.; Duan, P.; Zong, G. Adaptive Neural Control of Nonlinear Nonstrict Feedback Systems With Full-State Constraints: A Novel Nonlinear Mapping Method. IEEE Trans. Neural Netw. Learn. Syst. 2023, 34, 999–1007. [Google Scholar] [CrossRef] [Scilit]
- Gheisarnejad, M.; Mirzavand, G.; Ardeshiri, R.R.; Andresen, B.; Khooban, M.H. Adaptive Speed Control of Electric Vehicles Based on Multi-Agent Fuzzy Q-Learning. IEEE Trans. Emerg. Top. Comput. Intell. 2023, 7, 102–110. [Google Scholar] [CrossRef] [Scilit]
- Zha, W.T.; Zhai, J.Y.; Fei, S.M. Global Adaptive Control for a Class of Uncertain Stochastic Nonlinear Systems with Unknown Output Gain. Int. J. Control. Autom. Syst. 2017, 15, 1125–1133. [Google Scholar] [CrossRef] [Scilit]
- Jiang, Y.; Zhai, J.Y. Global Sampled-Data Output Feedback Stabilization for a Class of Switched Stochastic Nonlinear Systems with Quantized Input and Unknown Output Gain. Trans. Inst. Meas. Control 2019, 41, 4511–4520. [Google Scholar] [CrossRef] [Scilit]
- Kim, H.; Kim, W. Active Fault-Tolerant Control for Steering Actuator Bias in Autonomous Vehicles Using Adaptive Sliding Mode Observer. Sensors 2026, 26, 1680. [Google Scholar] [CrossRef] [Scilit]
- Zhao, L.; Chen, S. Hierarchical Fuzzy Adaptive Observer-Based Fault-Tolerant Consensus Tracking for High-Order Nonlinear Multi-Agent Systems Under Actuator and Sensor Faults. Sensors 2026, 26, 252. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Bekhiti, A.; Souanef, T.; Toubakh, H.; Horri, N.; Kafi, M.R.; Bouzid, Z. Adaptive UAV Control with Sensor and Actuator Faults Recovery. Aerospace 2025, 12, 261. [Google Scholar] [CrossRef] [Scilit]
- Yu, D.; Yang, M.; Liu, Y.J.; Wang, Z.; Chen, C.L.P. Adaptive Fuzzy Tracking Control for Uncertain Nonlinear Systems With Multiple Actuators and Sensors Faults. IEEE Trans. Fuzzy Syst. 2023, 31, 104–116. [Google Scholar]
- Wang, X.; Zhou, Y.; Huang, T.; Chakrabarti, P. Event-Triggered Adaptive Fault-Tolerant Control for a Class of Nonlinear Multiagent Systems With Sensor and Actuator Faults. IEEE Trans. Circuits Syst. I Regul. Pap. 2022, 69, 4203–4214. [Google Scholar] [CrossRef] [Scilit]
- Wang, H.; Ma, J.; Zhao, X.; Niu, B.; Chen, M.; Wang, W. Adaptive Fuzzy Fixed-Time Control for High-Order Nonlinear Systems With Sensor and Actuator Faults. IEEE Trans. Fuzzy Syst. 2023, 31, 2658–2668. [Google Scholar]
- Zhang, W.; Xu, D.; Jiang, B.; Shi, P. Virtual-Sensor-Based Model-Free Adaptive Fault-Tolerant Constrained Control for Discrete-Time Nonlinear Systems. IEEE Trans. Circuits Syst. I Regul. Pap. 2022, 69, 4191–4202. [Google Scholar] [CrossRef] [Scilit]
- Feng, J.; Zhao, D.; Yan, X.G.; Spurgeon, S.K. Output Feedback Backstepping Control for Nonlinear Systems Using an Adaptive Finite-Time Sliding Mode Observer. IMA J. Math. Control Inf. 2023, 40, 306–331. [Google Scholar]
- Zhai, D.; Chen, M.; Jiang, B. Output feedback adaptive sensor failure compensation for a class of parametric strict-feedback systems. Automatica 2018, 97, 48–57. [Google Scholar]
- Zhang, J.; Xiang, Z. Adaptive decentralized sensor failure compensation control for nonlinear switched interconnected systems with average dwell time. Int. J. Robust Nonlinear Control 2021, 31, 4000–4016. [Google Scholar] [CrossRef] [Scilit]
- Zhang, M.; Jiang, K.; Li, B.; Li, M.; Guo, Z. Adaptive Asymptotic Tracking Control of MIMO Nonlinear Systems Subject to Asymmetric Full-State Constraints: A Removing Feasibility Condition Approach. Mathematics 2026, 14, 806. [Google Scholar] [CrossRef] [Scilit]
- Chang, S.; Bai, J.; Wen, H.; Wei, S. Disturbance Observer-Based Saturation-Tolerant Prescribed Performance Control for Nonlinear Multi-Agent Systems. Electronics 2025, 14, 3310. [Google Scholar]
- Zhang, Y.; Dai, J.; Liu, Z.; Tang, R.; Zheng, G.; Wang, J. Fixed-Time Adaptive Event-Triggered Control for Uncertain Nonlinear Systems Under Full-State Constraints. Actuators 2025, 14, 231. [Google Scholar] [CrossRef] [Scilit]
- Zhang, C.; Chang, L.; Xing, L.; Zhang, X. Fixed-Time Stabilization of a Class of Strict-Feedback Nonlinear Systems via Dynamic Gain Feedback Control. IEEE/CAA J. Autom. Sin. 2023, 10, 403–410. [Google Scholar] [CrossRef] [Scilit]
- Wang, W.; Li, Y. Distributed Fuzzy Optimal Consensus Control of State-Constrained Nonlinear Strict-Feedback Systems. IEEE Trans. Cybern. 2023, 53, 2914–2929. [Google Scholar] [CrossRef] [Scilit]
- Li, Y.; Liu, Y.; Tong, S. Observer-Based Neuro-Adaptive Optimized Control of Strict-Feedback Nonlinear Systems With State Constraints. IEEE Trans. Neural Netw. Learn. Syst. 2022, 33, 3131–3145. [Google Scholar] [CrossRef] [Scilit]
- Cui, B.; Xia, Y.; Liu, K.; Shen, G. Finite-Time Tracking Control for a Class of Uncertain Strict-Feedback Nonlinear Systems With State Constraints: A Smooth Control Approach. IEEE Trans. Neural Netw. Learn. Syst. 2020, 31, 4920–4932. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Yuan, X.; Chen, B.; Lin, C. Neural Adaptive Fixed-Time Control for Nonlinear Systems With Full-State Constraints. IEEE Trans. Cybern. 2023, 53, 3048–3059. [Google Scholar] [CrossRef] [Scilit]
- Shen, G.; Huang, P.; Ma, Z.; Zhang, F.; Xia, Y. Dynamic Event-Based Adaptive Fixed-Time Control for Uncertain Strict-Feedback Nonlinear Systems With State Constraints. IEEE Trans. Cybern. 2024, 54, 4630–4642. [Google Scholar] [CrossRef] [Scilit]
- Zuo, G.; Wang, Y. Adaptive Prescribed Finite Time Control for Strict-Feedback Systems. IEEE Trans. Autom. Control 2023, 68, 5729–5736. [Google Scholar] [CrossRef] [Scilit]
- Zhao, B.; Yao, X. Asymptotic Adaptive Tracking Control Based on Disturbance Observer for Non-Strict Feedback Nonlinear Systems. IEEE Trans. Autom. Sci. Eng. 2025, 22, 9449–9456. [Google Scholar] [CrossRef] [Scilit]
- Krishnan, R. Electric Motor Drives: Modeling, Analysis, and Control; Prentice Hall: Upper Saddle River, NJ, USA, 2001. [Google Scholar]
- Nizami, T.K.; Chakravarty, A.; Mahanta, C. Design and implementation of a neuro-adaptive backstepping controller for buck converter fed PMDC-motor. Control Eng. Pract. 2017, 58, 78–87. [Google Scholar] [CrossRef] [Scilit]





| Performance Metrics | ERMS | MAE | IAE |
|---|---|---|---|
| Ours | 0.010867 | 0.217339 | |
| In [17] | 0.011610 | 0.232208 |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Wang, Z.; Hashimoto, S.; Nie, P.; Xu, S.; Kawaguchi, T. Output Feedback Adaptive Tracking Control for Uncertain Strict-Feedback Nonlinear Systems with Full-State Constraints and Unknown Output Gain. Sensors 2026, 26, 3084. https://doi.org/10.3390/s26103084
Wang Z, Hashimoto S, Nie P, Xu S, Kawaguchi T. Output Feedback Adaptive Tracking Control for Uncertain Strict-Feedback Nonlinear Systems with Full-State Constraints and Unknown Output Gain. Sensors. 2026; 26(10):3084. https://doi.org/10.3390/s26103084
Chicago/Turabian StyleWang, Zhenlin, Seiji Hashimoto, Pengqiang Nie, Song Xu, and Takahiro Kawaguchi. 2026. "Output Feedback Adaptive Tracking Control for Uncertain Strict-Feedback Nonlinear Systems with Full-State Constraints and Unknown Output Gain" Sensors 26, no. 10: 3084. https://doi.org/10.3390/s26103084
APA StyleWang, Z., Hashimoto, S., Nie, P., Xu, S., & Kawaguchi, T. (2026). Output Feedback Adaptive Tracking Control for Uncertain Strict-Feedback Nonlinear Systems with Full-State Constraints and Unknown Output Gain. Sensors, 26(10), 3084. https://doi.org/10.3390/s26103084