Article

Integrated Decision and Motion Planning for Highways with Multiple Objects Using a Naturalistic Driving Study


1
College of Mechanical and Vehicle Engineering, Chongqing University, Chongqing 400044, China
2
Western Science City Intelligent and Connected Vehicle Innovation Center (Chongqing) Co., Ltd., Chongqing 400015, China
*
Author to whom correspondence should be addressed.
Sensors 2025, 25(1), 26; https://doi.org/10.3390/s25010026
Submission received: 3 December 2024 / Revised: 17 December 2024 / Accepted: 18 December 2024 / Published: 24 December 2024
(This article belongs to the Special Issue Intelligent Control Systems for Autonomous Vehicles)

Abstract

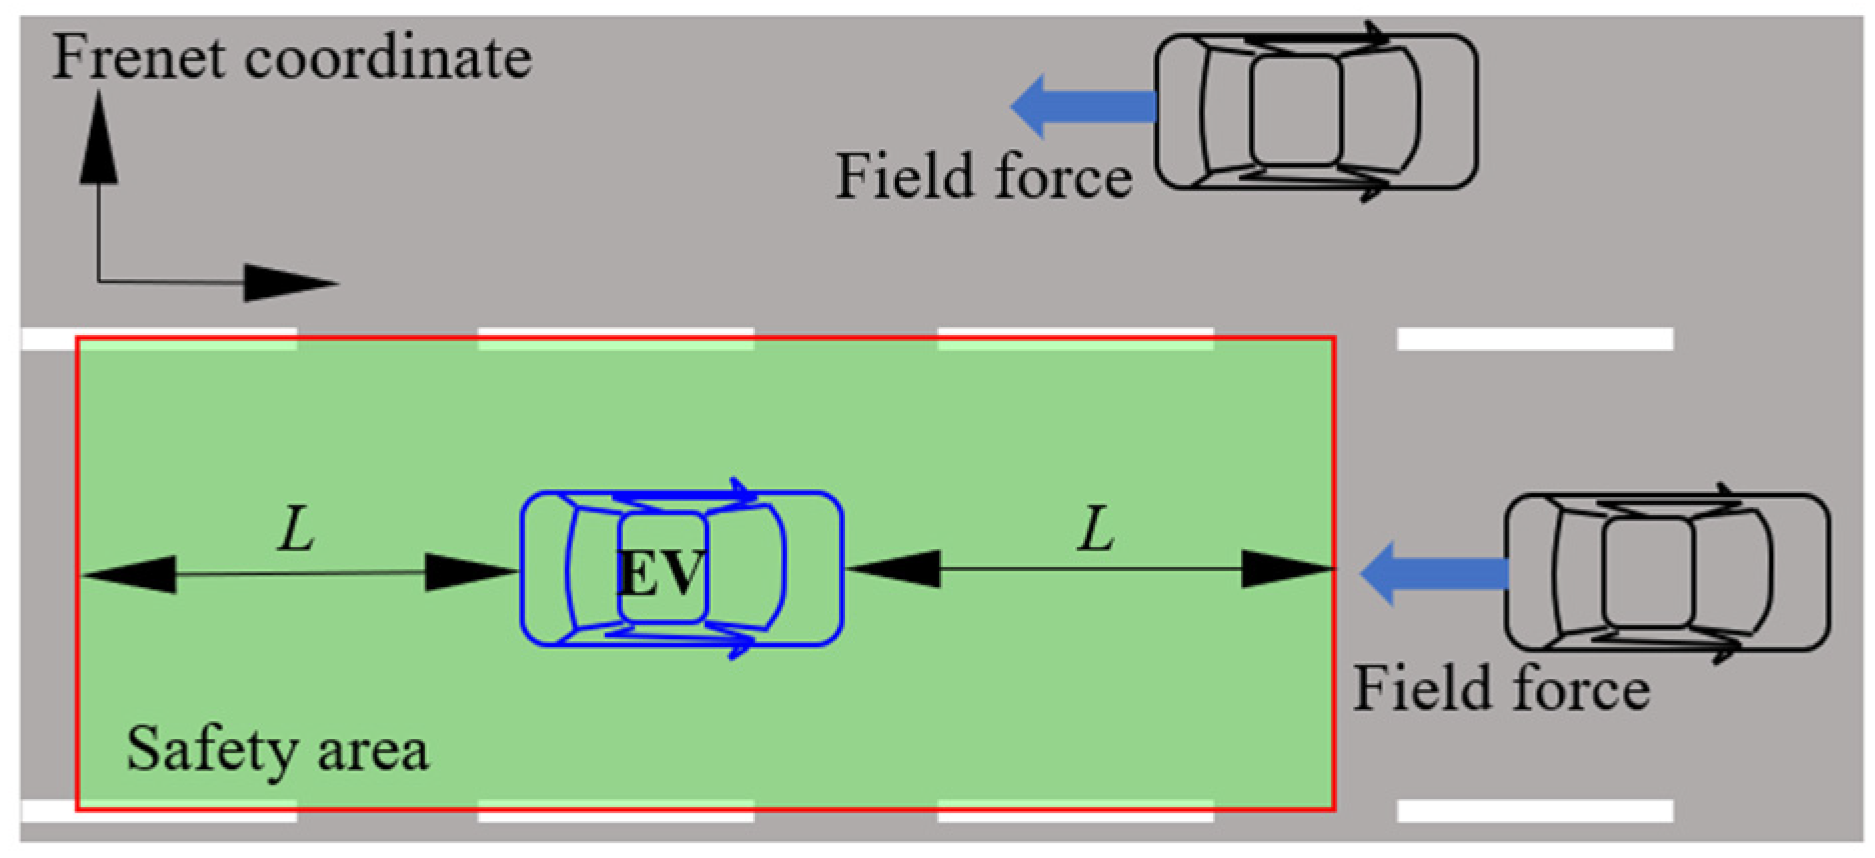
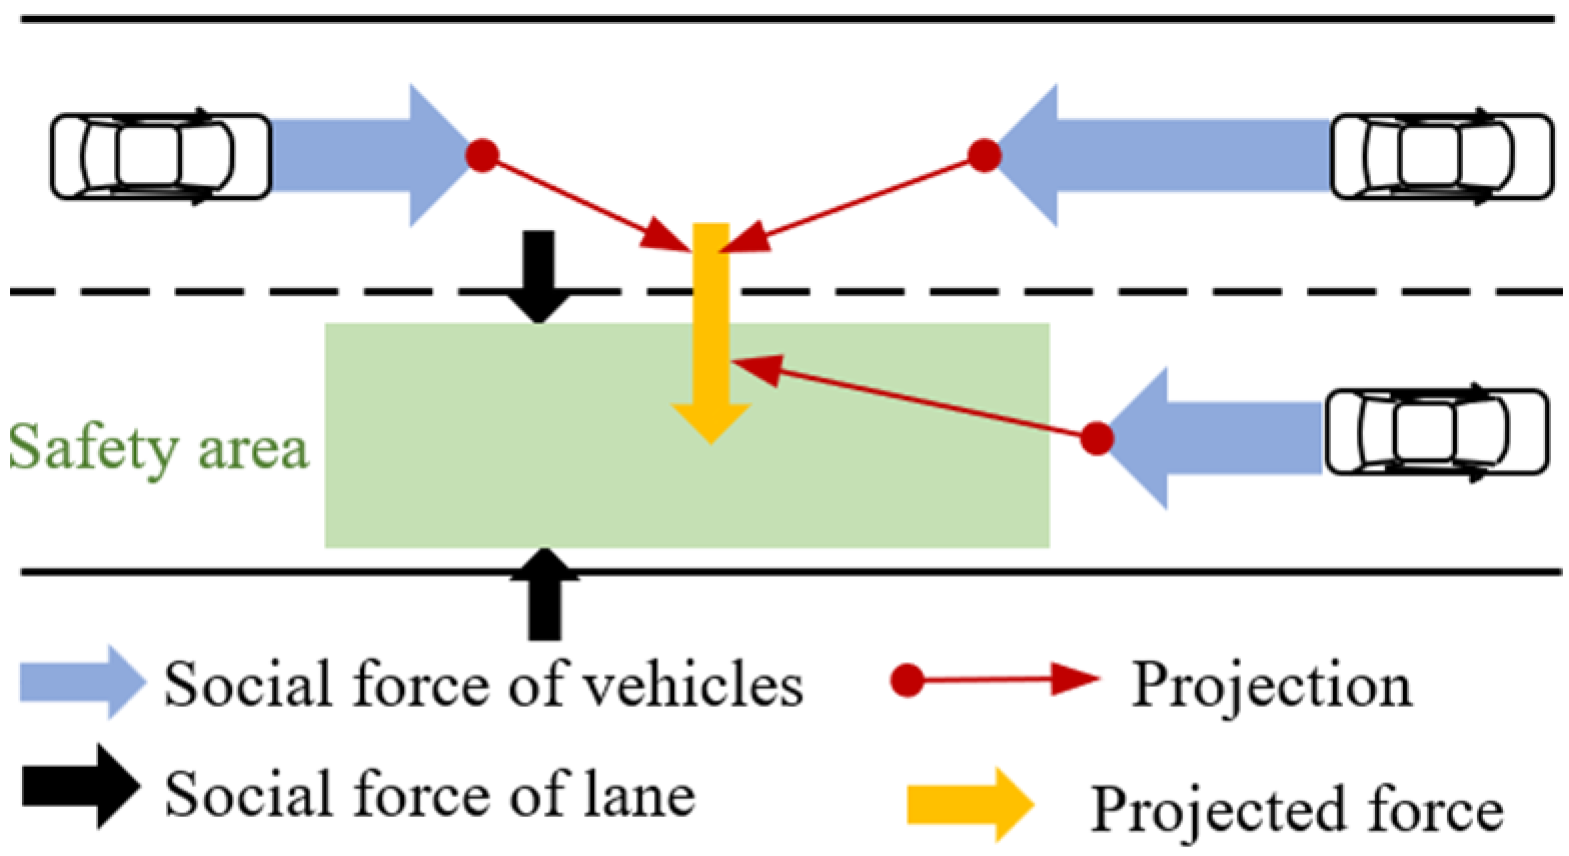
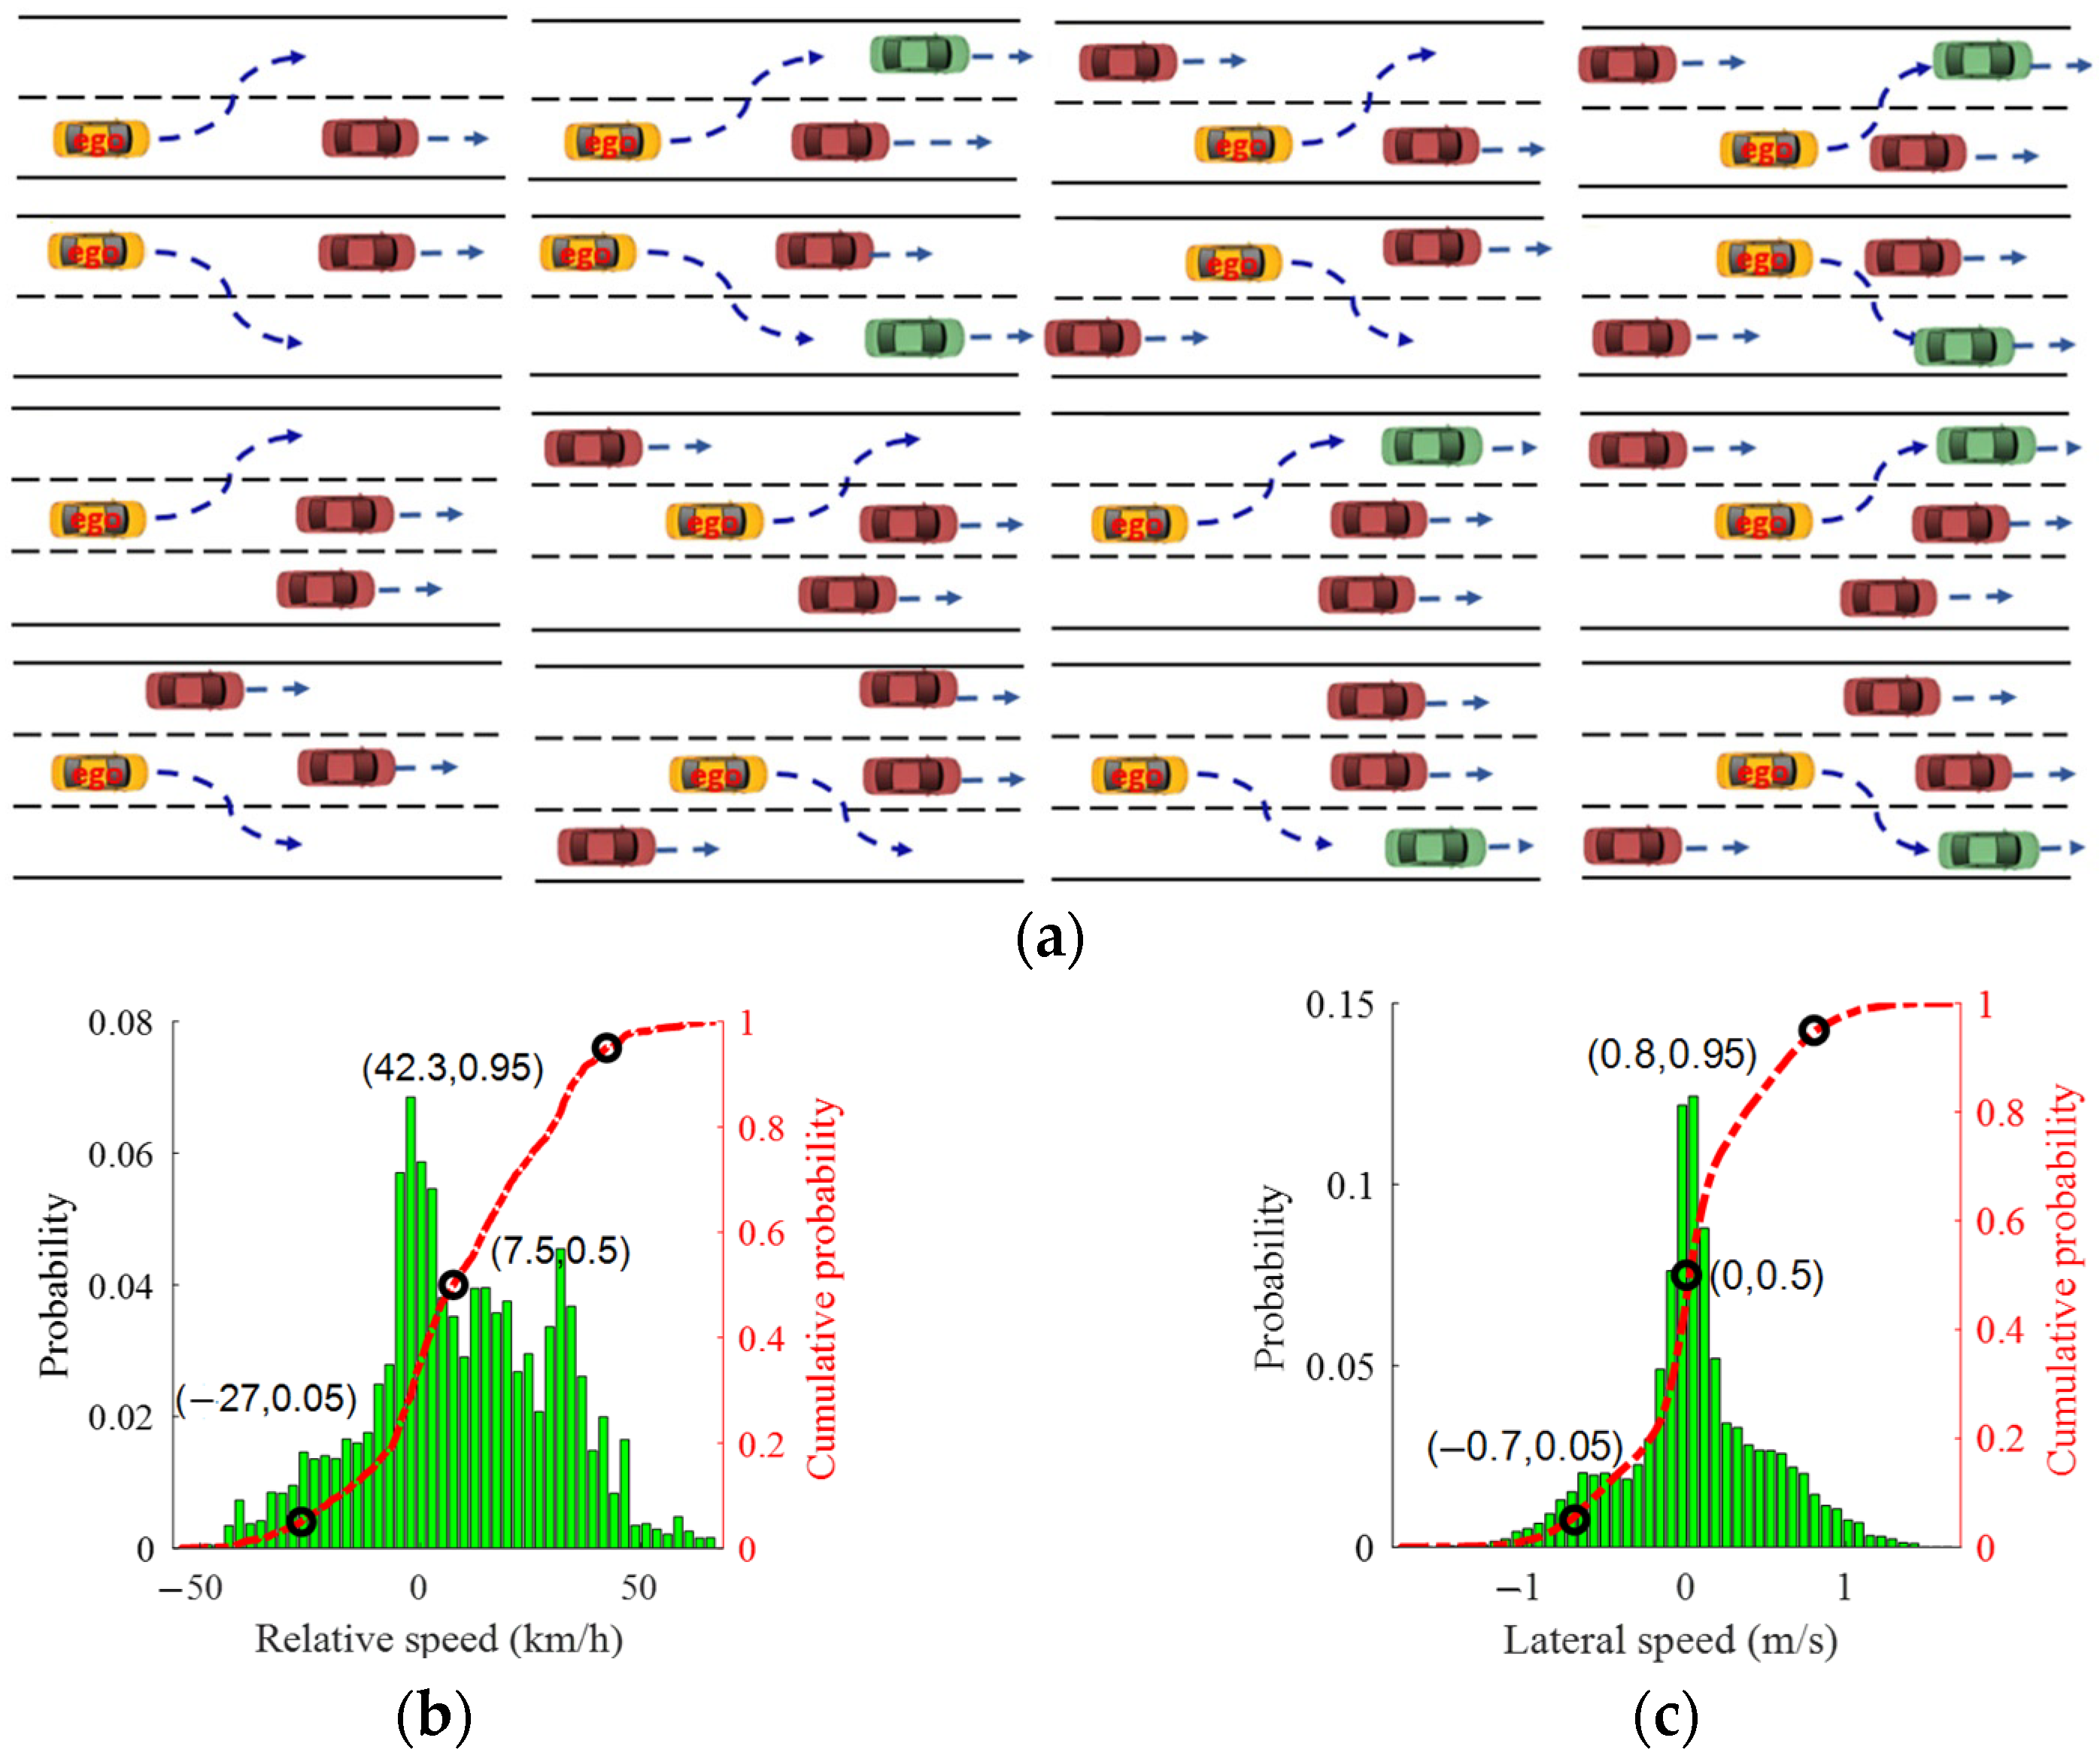
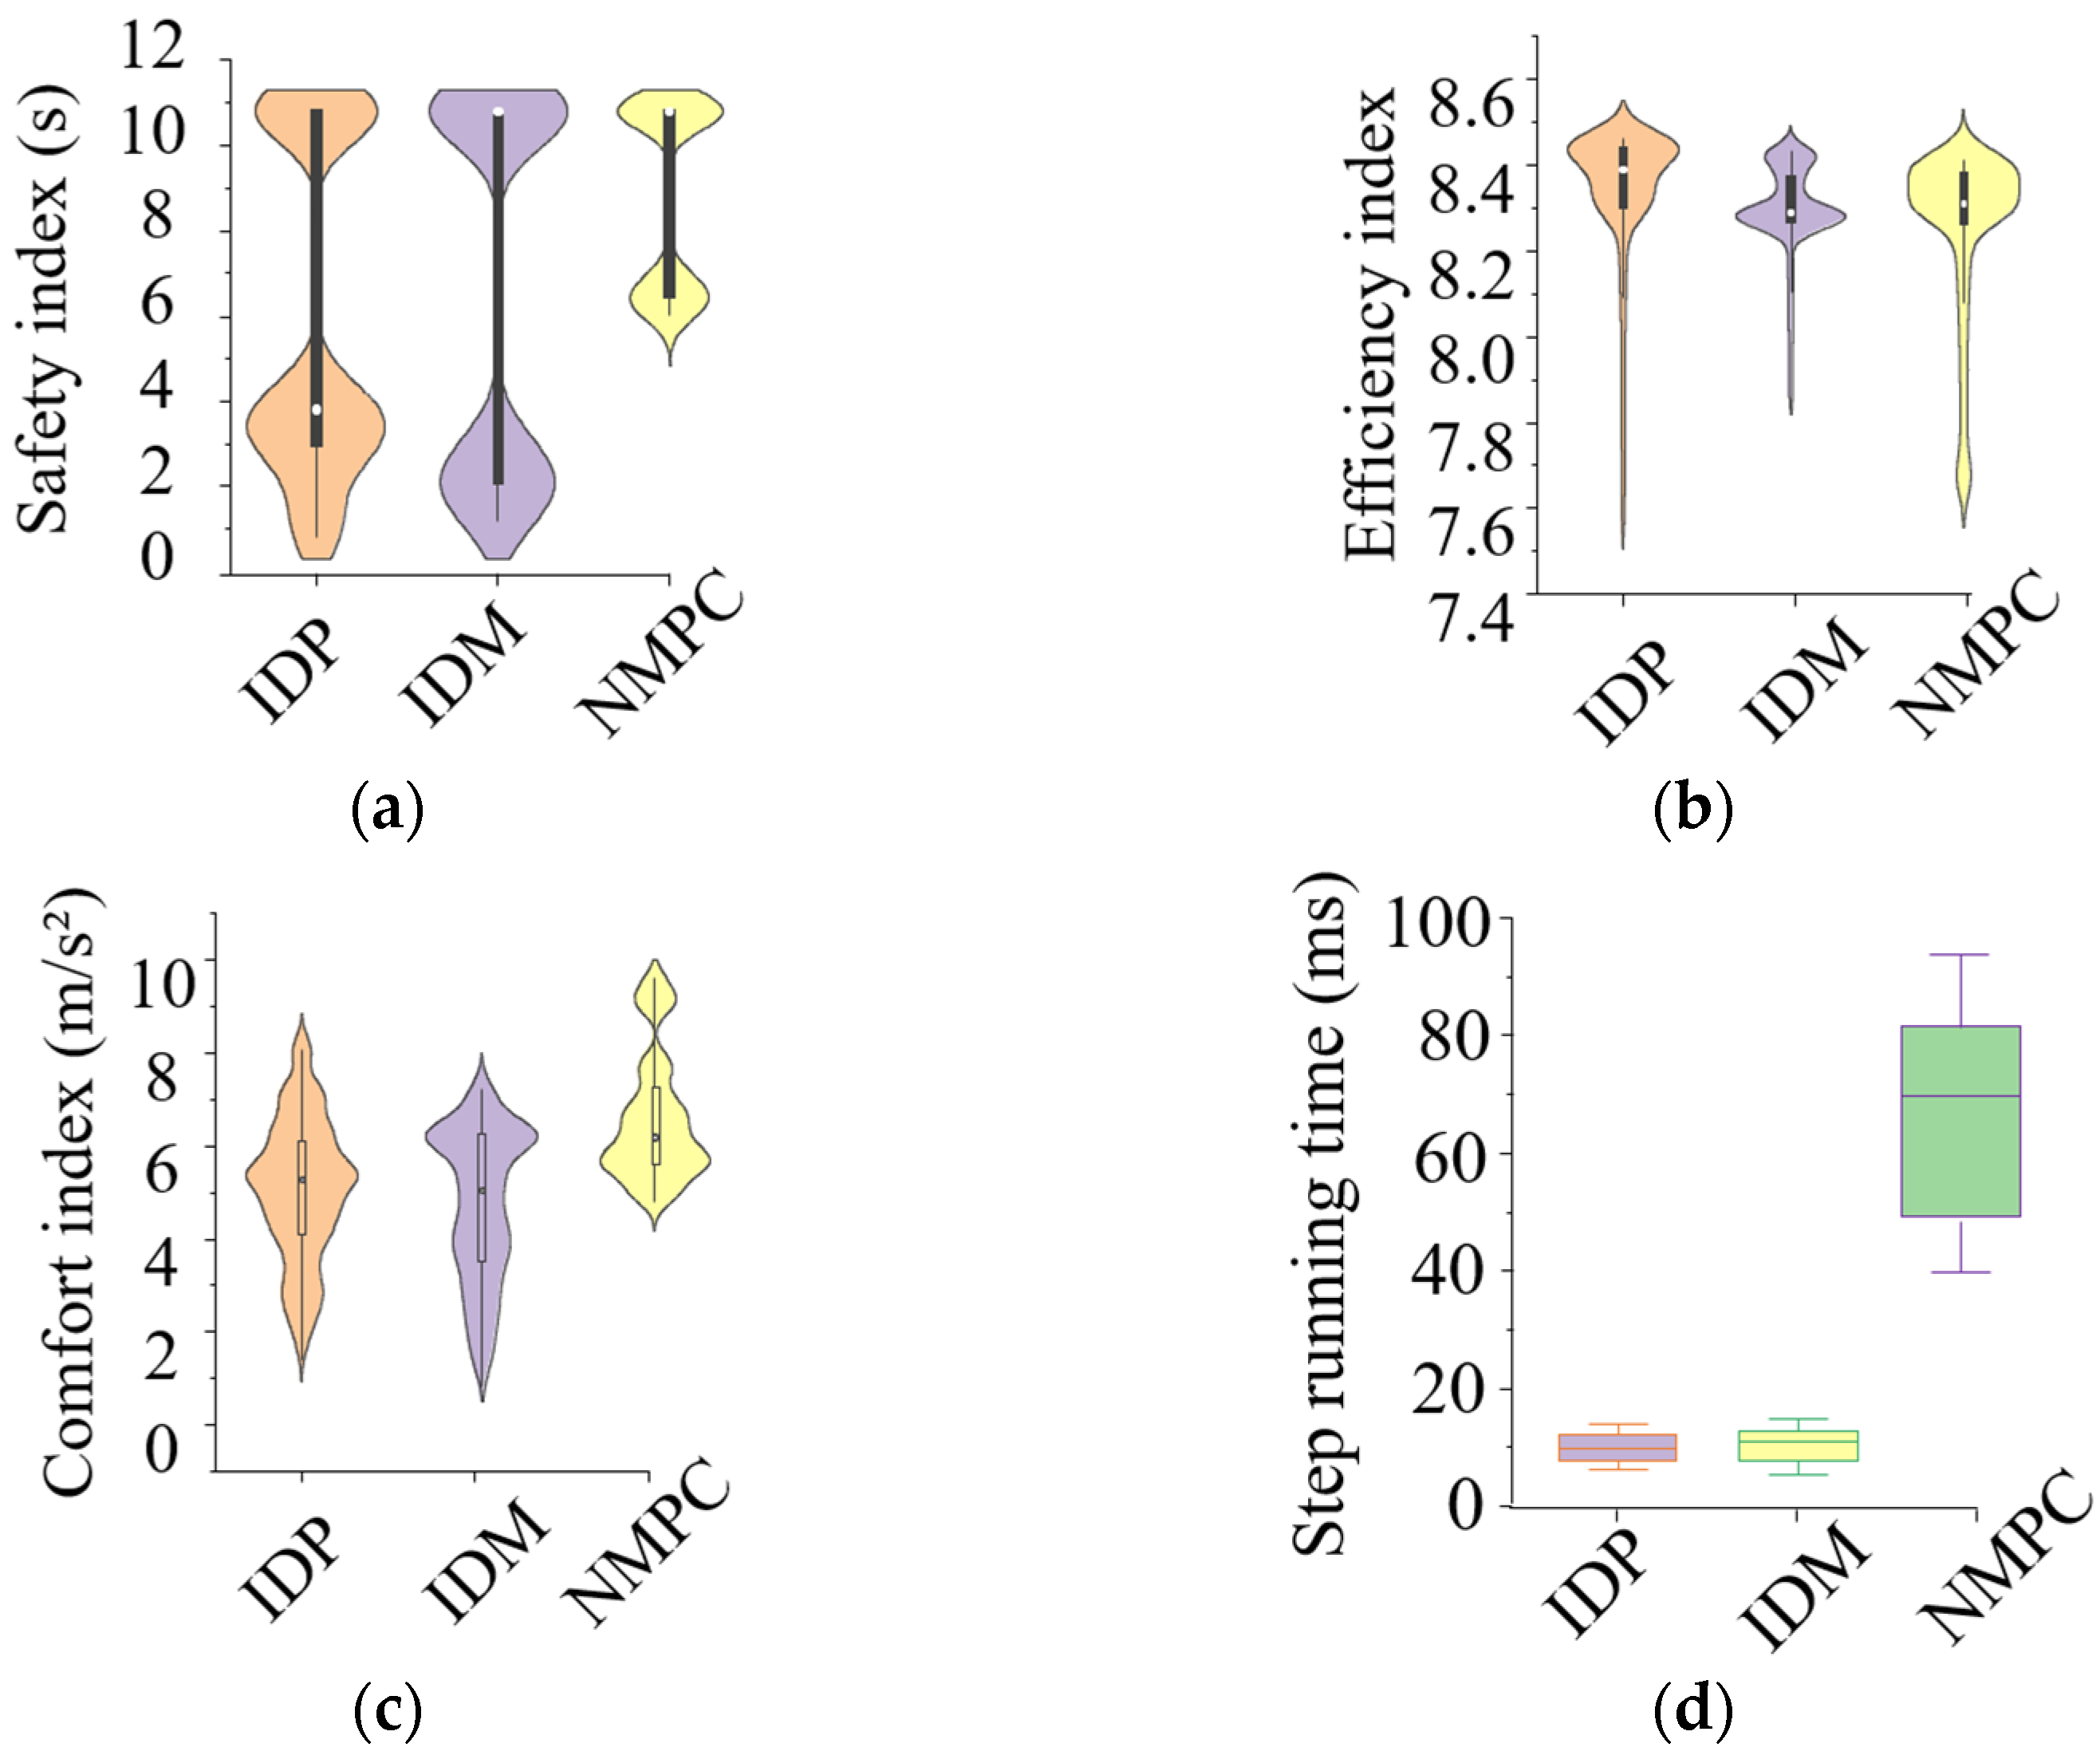
With the rise in the intelligence levels of automated vehicles, increasing numbers of modules of automated driving systems are being combined to achieve better performance and adaptability by reducing information loss. In this study, an integrated decision and motion planning system is designed for multi-object highways. A two-layer structure is presented to decouple the influence of the traffic environment and the dynamic control of ego vehicles using the cognitive safety area, the size of which is determined by naturalistic driving behavior. The artificial potential field method is used to comprehensively describe the influence of all external objects on the cognitive safety area, the lateral motion dynamics of which are determined by the attention mechanism of the human driver during lane changes. Then, the interaction between the designed cognitive safety area and the ego vehicle can be simplified into a spring-damping system, and the desired dynamic states of the ego vehicle can be obtained analytically for better computational efficiency. The effectiveness of this on improving traffic efficiency, driving comfort, safety, and real-time performance was validated using several comparative tests utilizing complicated scenarios with multiple vehicles.
Keywords: automated vehicle; motion planning; driving decision; artificial potential field; naturalistic driving study automated vehicle; motion planning; driving decision; artificial potential field; naturalistic driving study