Article

Multi-Task Foreground-Aware Network with Depth Completion for Enhanced RGB-D Fusion Object Detection Based on Transformer

1
School of Computer Engineering and Science, Shanghai University, No. 99 Shangda Road, Shanghai 200444, China
2
School of Mechatronic Engineering and Automation, Shanghai University, No. 99 Shangda Road, Shanghai 200444, China
3
School of Artificial Intelligence, Shanghai University, No. 99 Shangda Road, Shanghai 200444, China
*
Author to whom correspondence should be addressed.
Sensors 2024, 24(7), 2374; https://doi.org/10.3390/s24072374
Submission received: 8 January 2024 / Revised: 29 March 2024 / Accepted: 4 April 2024 / Published: 8 April 2024
(This article belongs to the Special Issue Multi-Sensor Fusion for Target Detection and Tracking)

Abstract

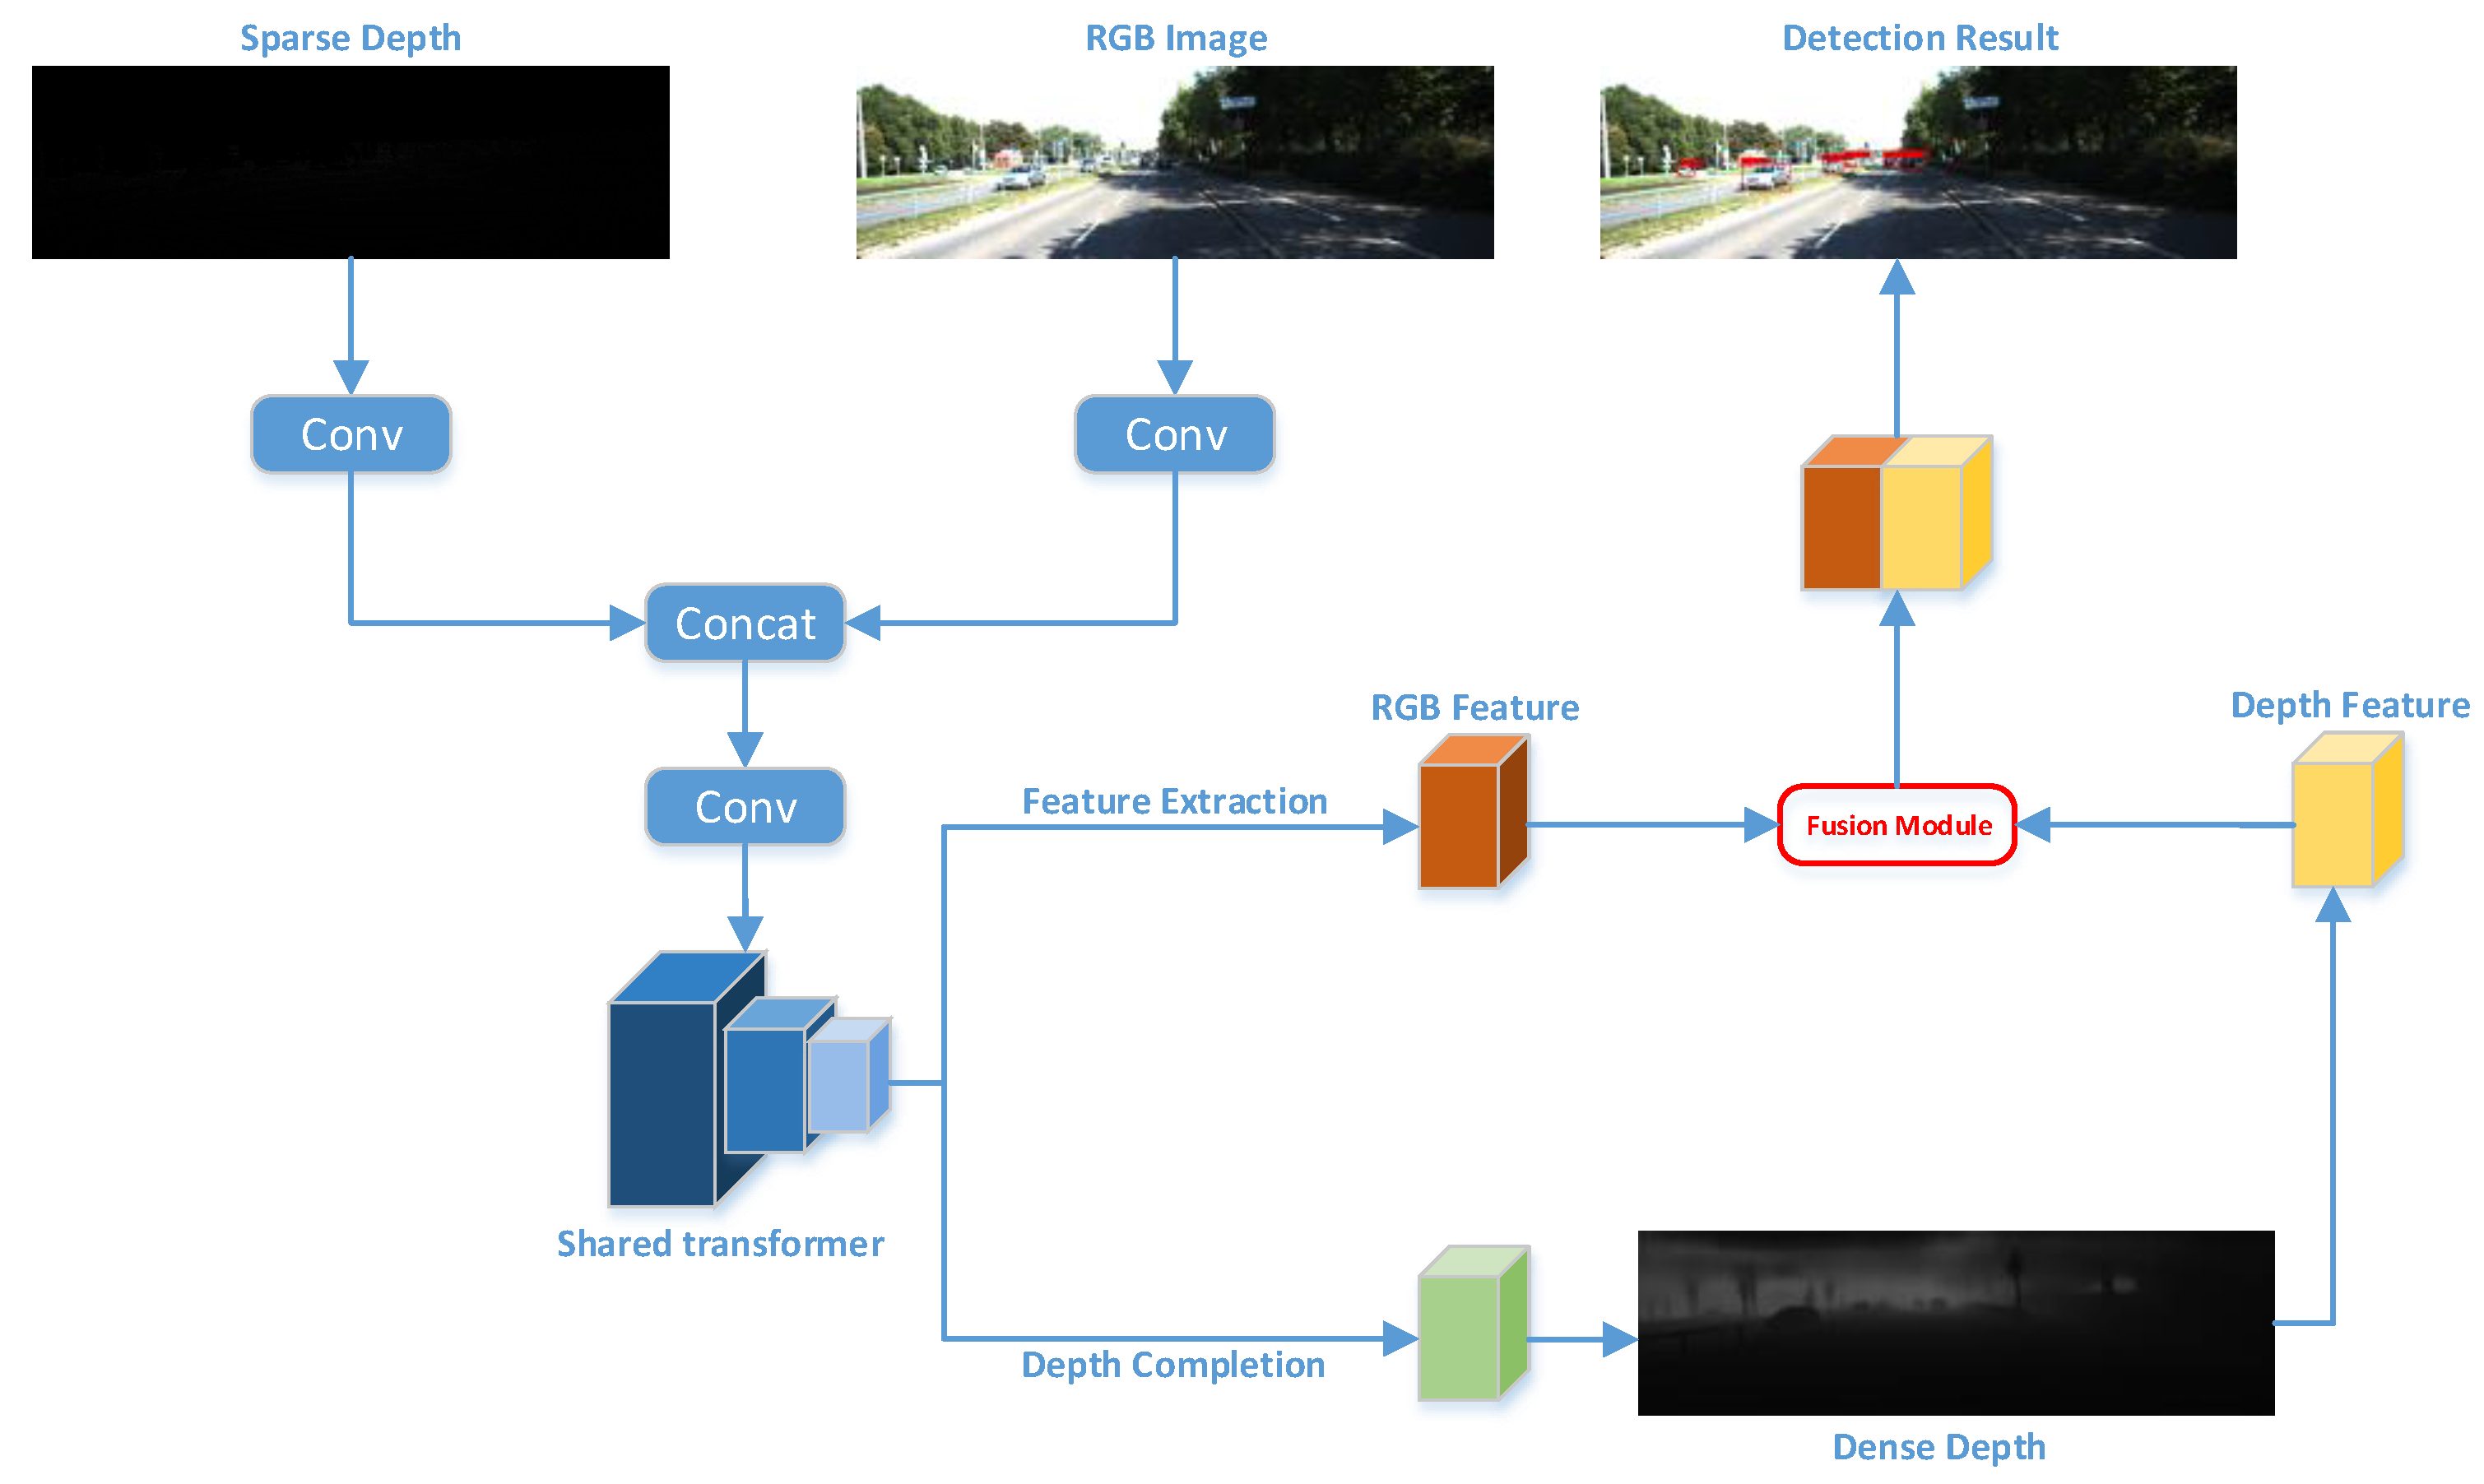
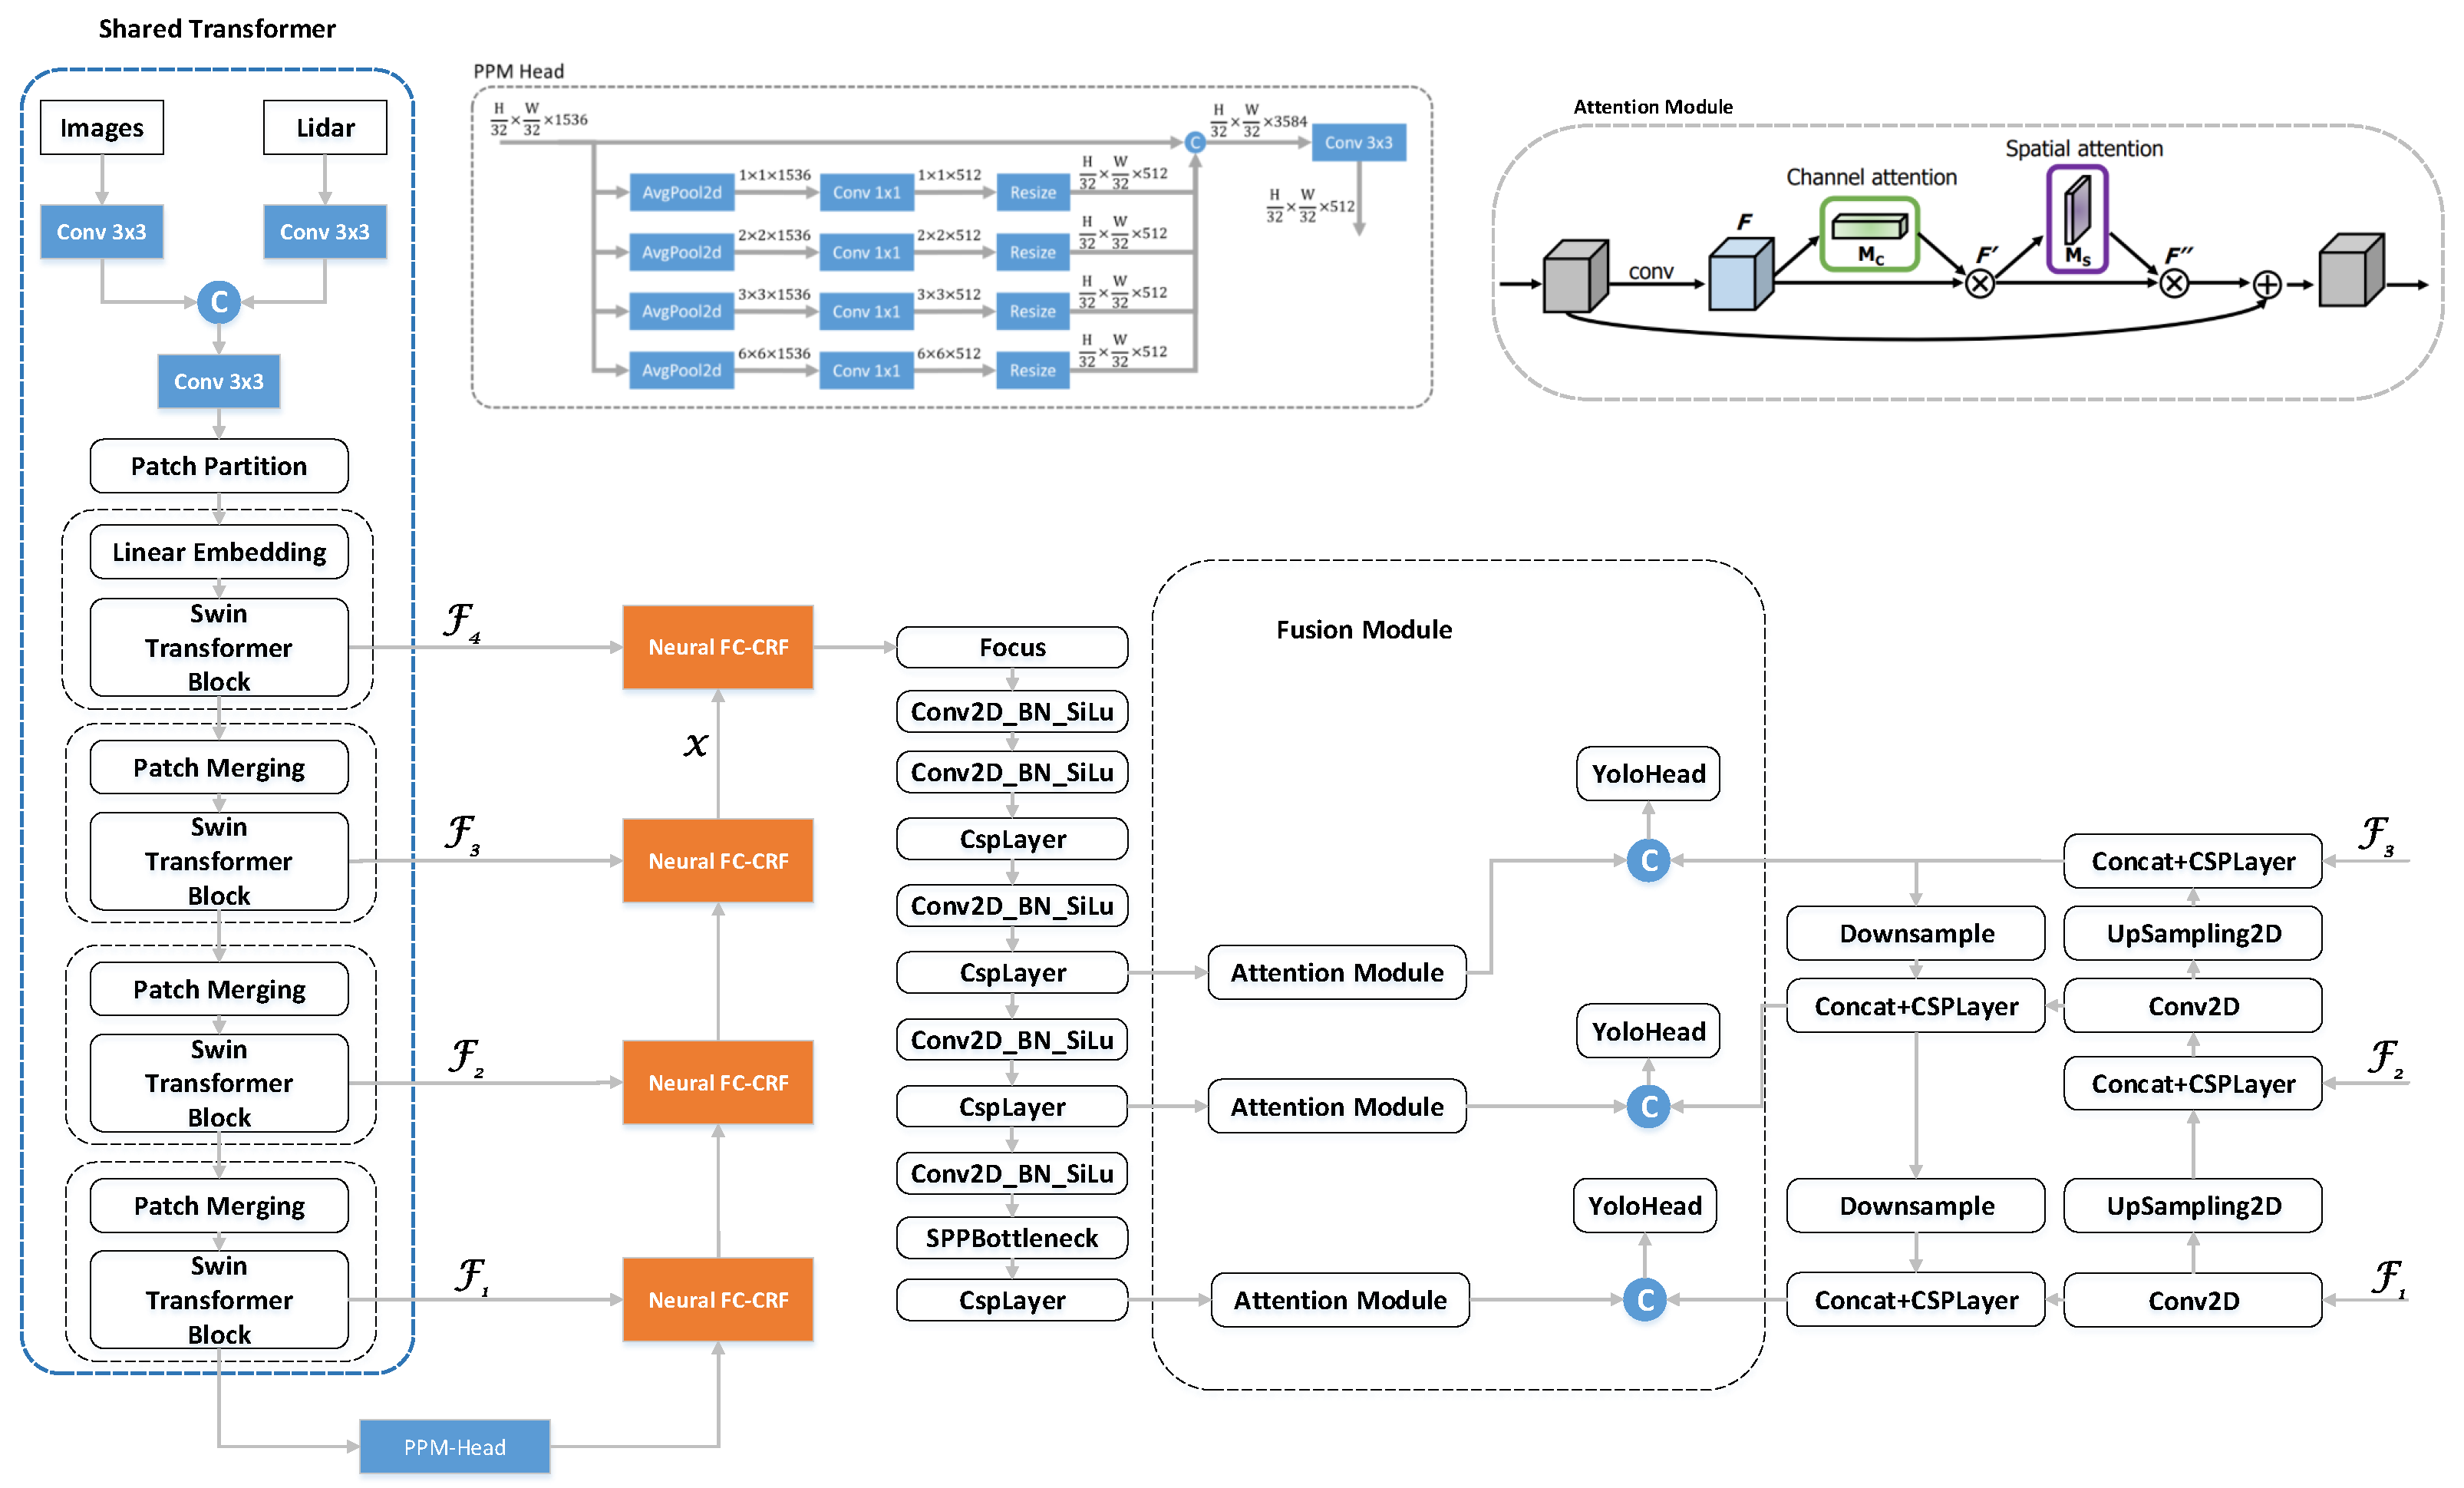
Fusing multiple sensor perceptions, specifically LiDAR and camera, is a prevalent method for target recognition in autonomous driving systems. Traditional object detection algorithms are limited by the sparse nature of LiDAR point clouds, resulting in poor fusion performance, especially for detecting small and distant targets. In this paper, a multi-task parallel neural network based on the Transformer is constructed to simultaneously perform depth completion and object detection. The loss functions are redesigned to reduce environmental noise in depth completion, and a new fusion module is designed to enhance the network’s perception of the foreground and background. The network leverages the correlation between RGB pixels for depth completion, completing the LiDAR point cloud and addressing the mismatch between sparse LiDAR features and dense pixel features. Subsequently, we extract depth map features and effectively fuse them with RGB features, fully utilizing the depth feature differences between foreground and background to enhance object detection performance, especially for challenging targets. Compared to the baseline network, improvements of 4.78%, 8.93%, and 15.54% are achieved in the difficult indicators for cars, pedestrians, and cyclists, respectively. Experimental results also demonstrate that the network achieves a speed of 38 fps, validating the efficiency and feasibility of the proposed method.
Keywords: point cloud data; YOLO; Transformer; multi-source feature fusion; depth completion point cloud data; YOLO; Transformer; multi-source feature fusion; depth completion