Review

Feature Sensing and Robotic Grasping of Objects with Uncertain Information: A Review


State Key Laboratory of Robotics and Systems, Harbin Institute of Technology, Harbin 150001, China
*
Author to whom correspondence should be addressed.
Co-first authors.
Sensors 2020, 20(13), 3707; https://doi.org/10.3390/s20133707
Submission received: 3 June 2020 / Revised: 23 June 2020 / Accepted: 30 June 2020 / Published: 2 July 2020
(This article belongs to the Collection Robotics, Sensors and Industry 4.0)

Abstract

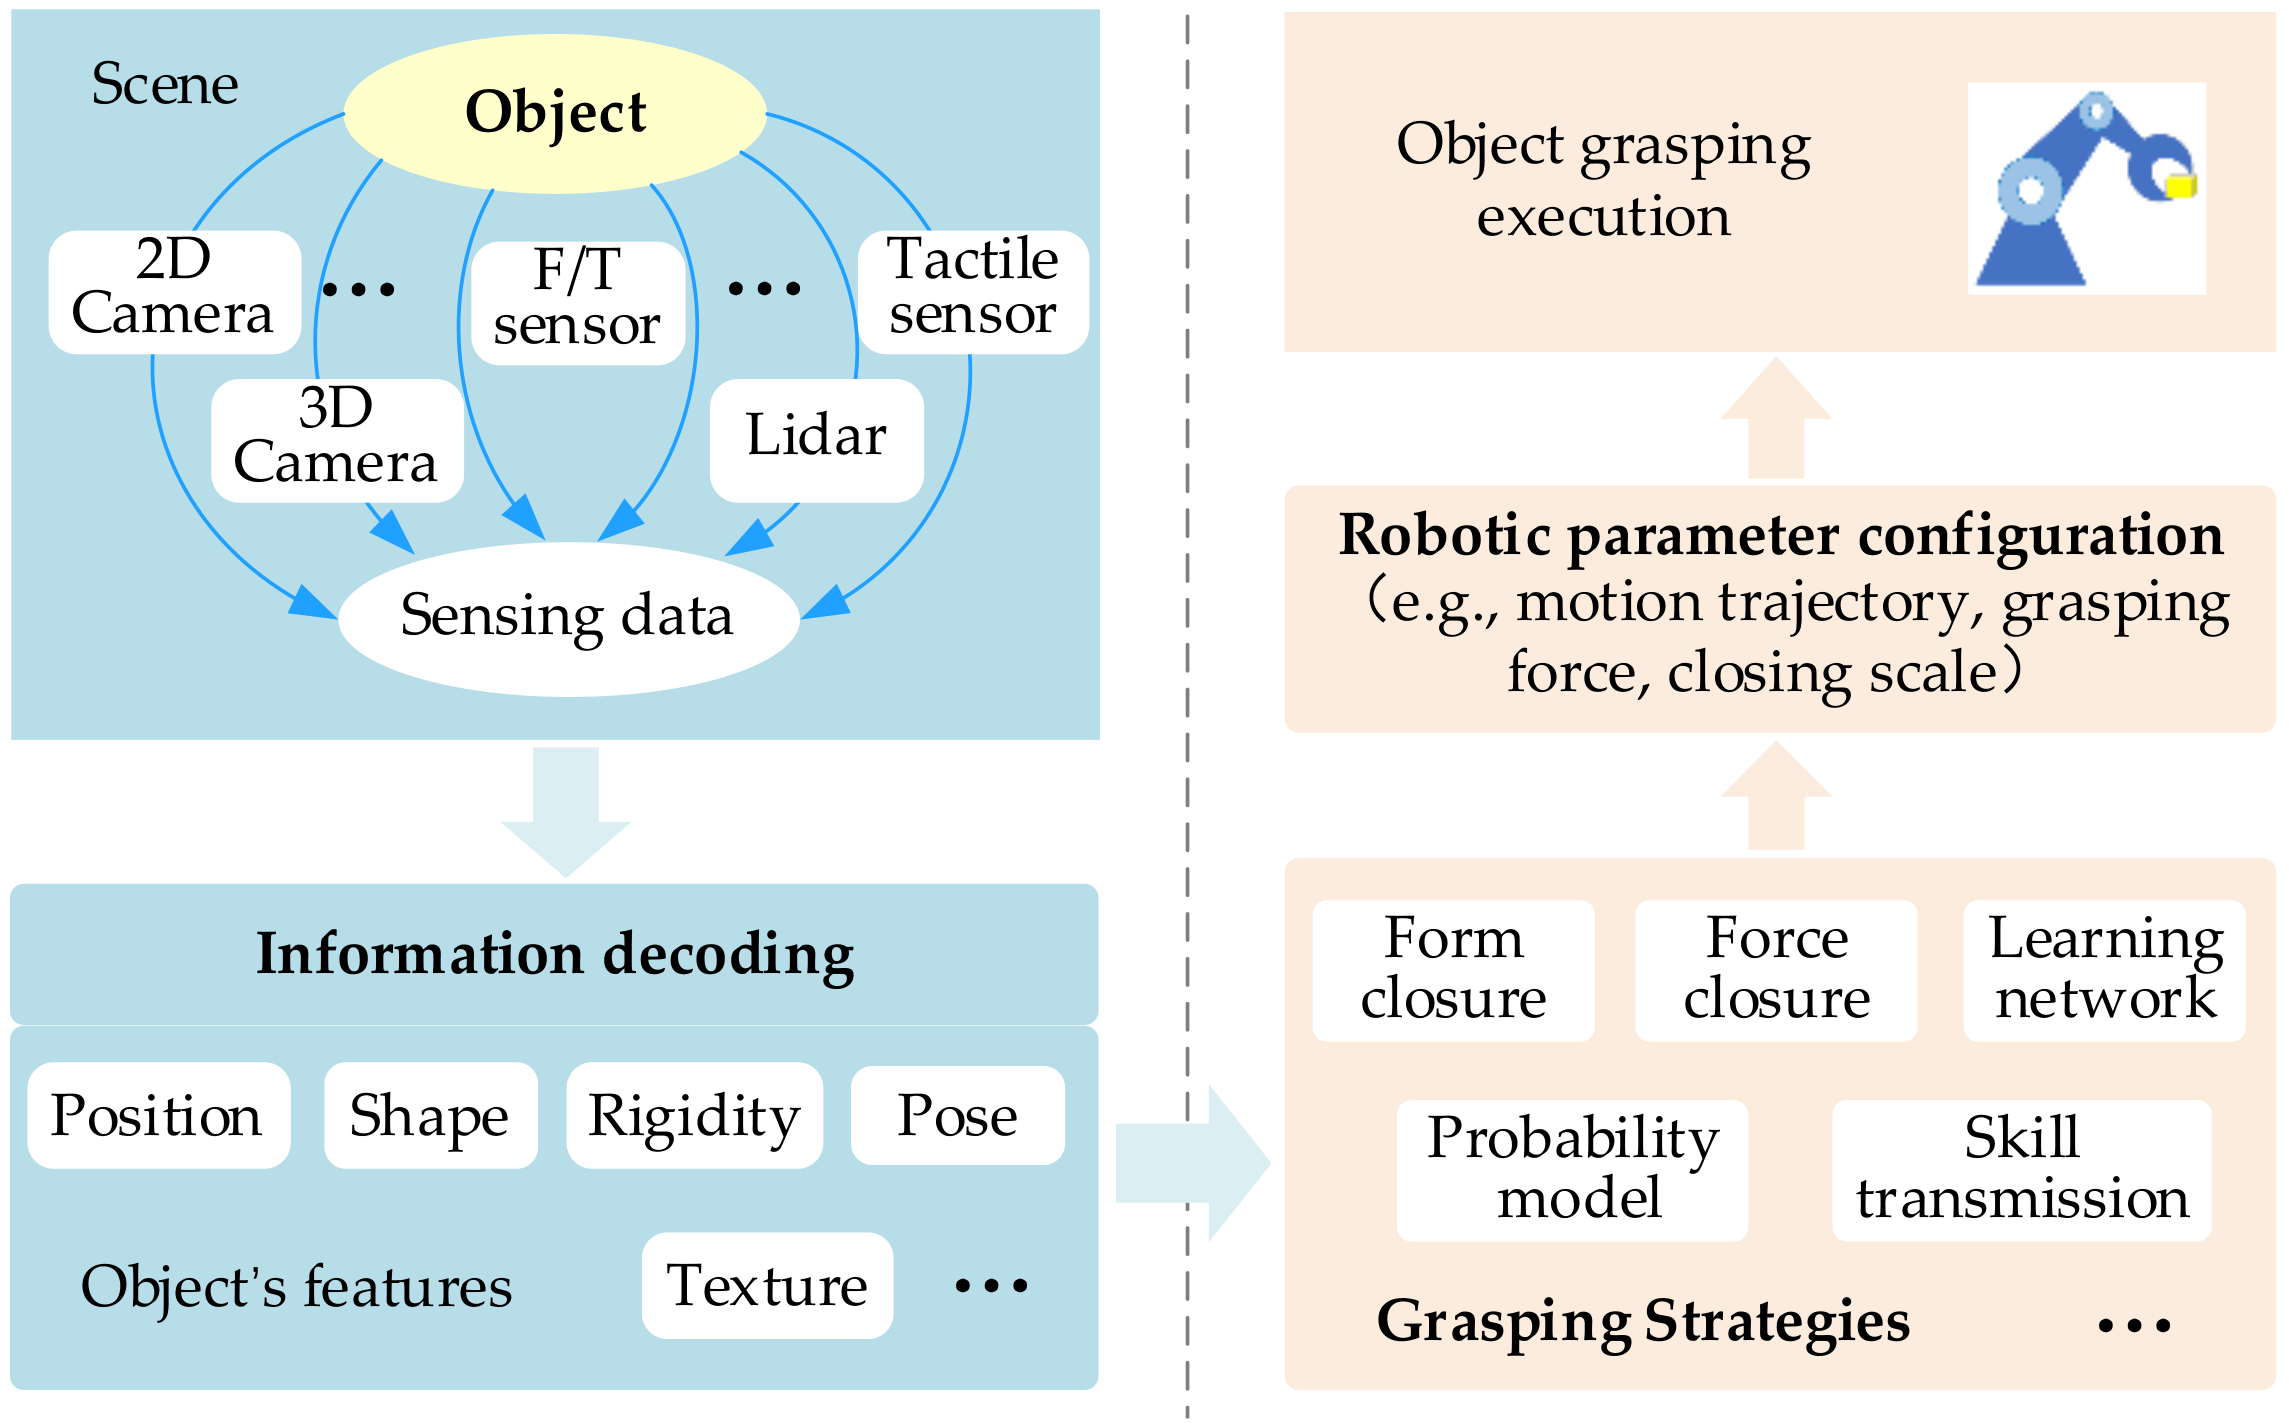
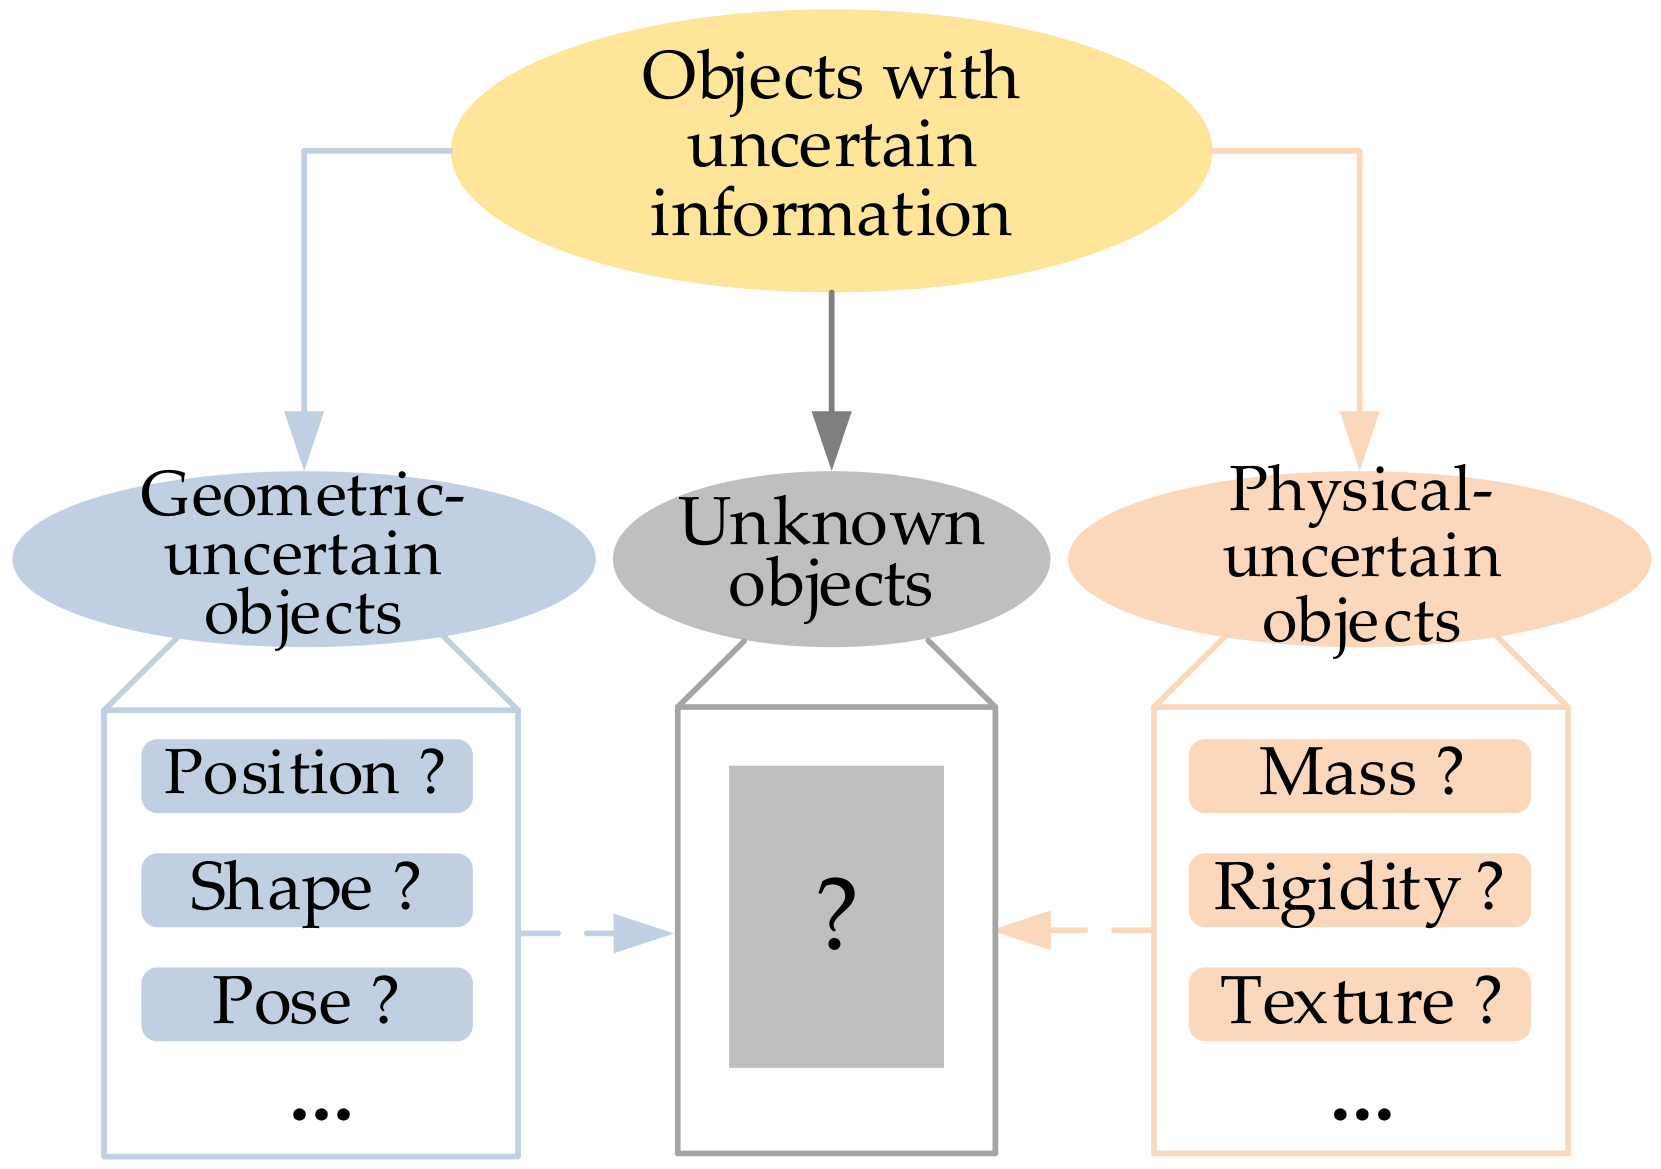
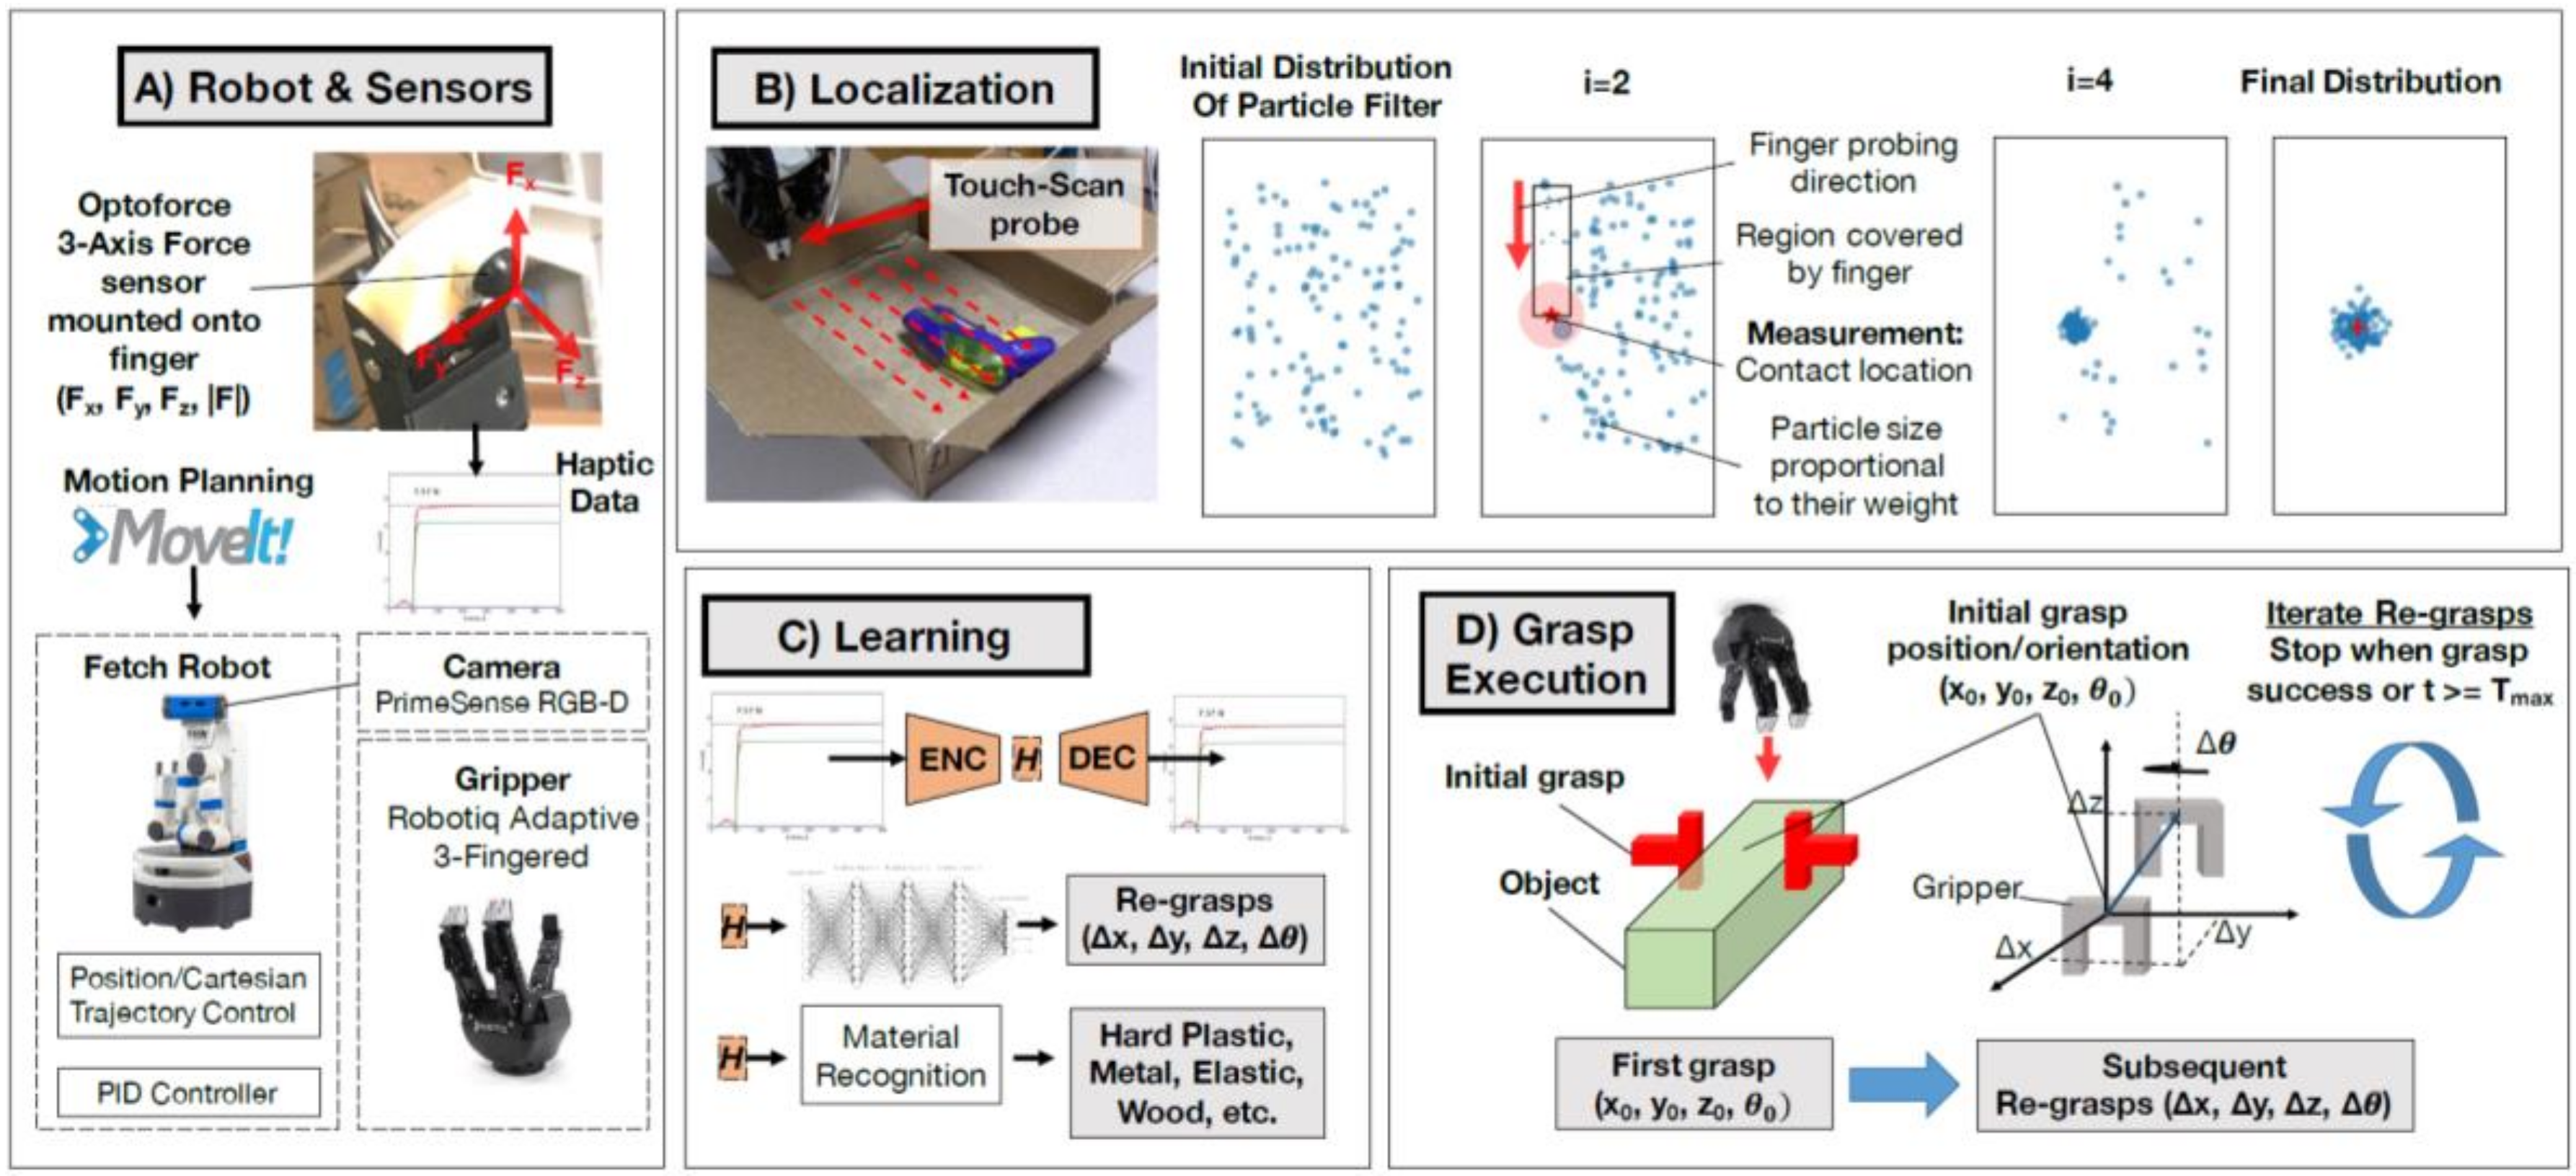
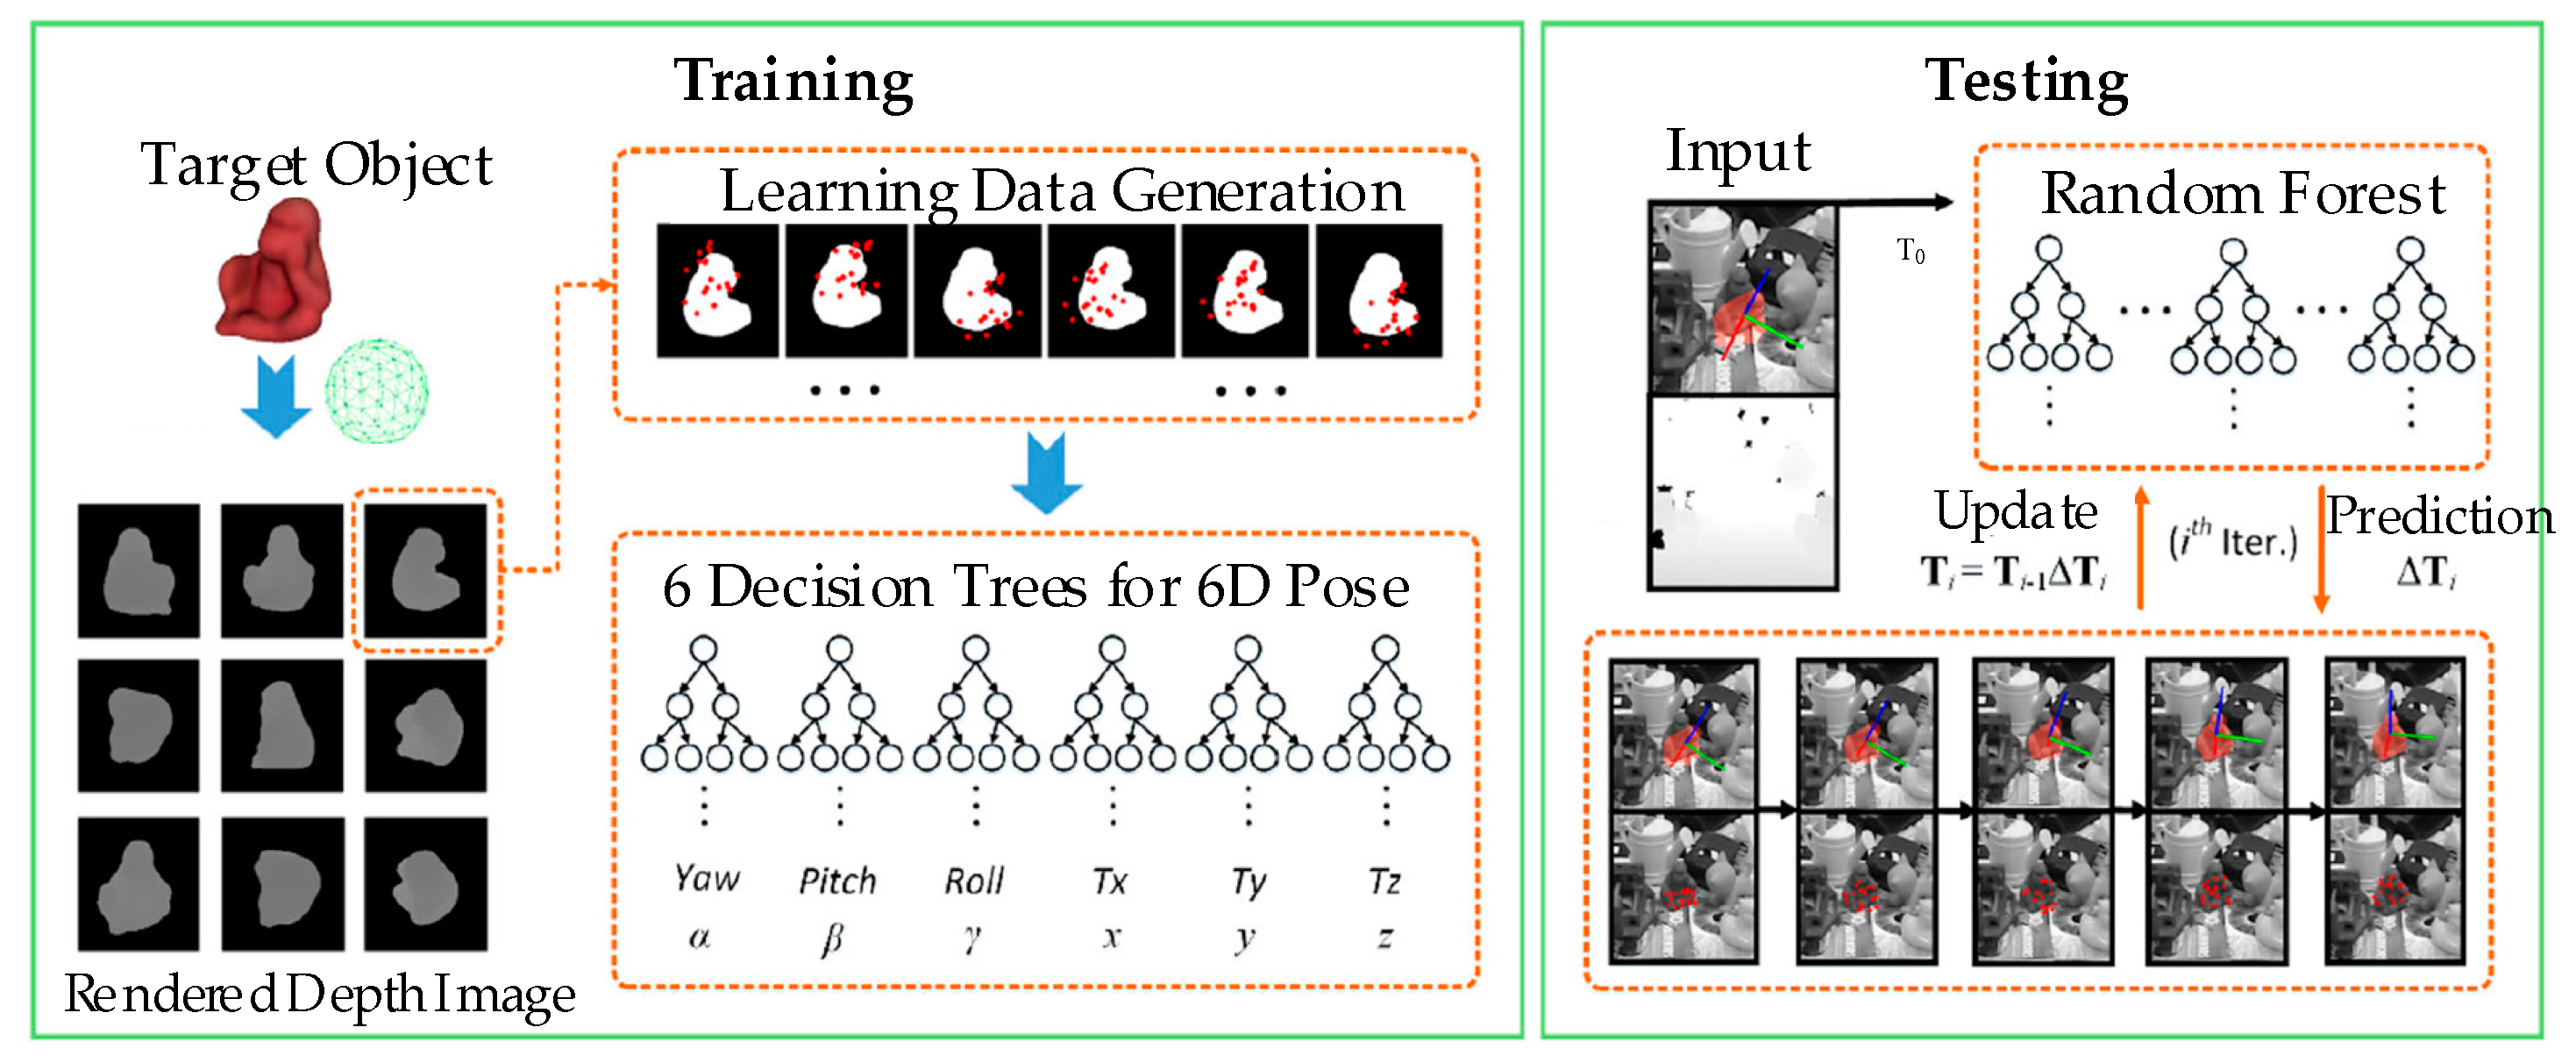
As there come to be more applications of intelligent robots, their task object is becoming more varied. However, it is still a challenge for a robot to handle unfamiliar objects. We review the recent work on the feature sensing and robotic grasping of objects with uncertain information. In particular, we focus on how the robot perceives the features of an object, so as to reduce the uncertainty of objects, and how the robot completes object grasping through the learning-based approach when the traditional approach fails. The uncertain information is classified into geometric information and physical information. Based on the type of uncertain information, the object is further classified into three categories, which are geometric-uncertain objects, physical-uncertain objects, and unknown objects. Furthermore, the approaches to the feature sensing and robotic grasping of these objects are presented based on the varied characteristics of each type of object. Finally, we summarize the reviewed approaches for uncertain objects and provide some interesting issues to be more investigated in the future. It is found that the object’s features, such as material and compactness, are difficult to be sensed, and the object grasping approach based on learning networks plays a more important role when the unknown degree of the task object increases.
Keywords: uncertain objects; geometric uncertainty; physical uncertainty; feature sensing; robotic grasping uncertain objects; geometric uncertainty; physical uncertainty; feature sensing; robotic grasping