Skip to Content
  • 2.5
    Impact Factor
  • 3.4
    CiteScore
  • 15 days
    Submission to First Decision
  • 4 days
    Acceptance to Publication

Future Transportation

Future Transportation is an international, peer-reviewed, open access journal on the civil engineering, economics, environment and geography, computer science and other transdisciplinary dimensions of transportation published bimonthly online by MDPI.
  • Open Access— free for readers, with article processing charges (APC) paid by authors or their institutions.
  • High Visibility: indexed within ESCI (Web of Science), Scopus, EBSCO, and other databases.
  • Rapid Publication: manuscripts are peer-reviewed and a first decision is provided to authors approximately 14.6 days after submission; acceptance to publication is undertaken in 3.5 days (median values for papers published in this journal in the first half of 2026).
  • Journal Rank: CiteScore - Q2 (Engineering (miscellaneous)).
  • Recognition of Reviewers: Reviewers whose reports are timely and of high quality receive an APC discount voucher for a future publication in an MDPI journal. Become a reviewer.
  • Future Transportation is a companion journal of Sustainability.

Get Alerted

Add your email address to receive forthcoming issues of this journal.

All Articles (735)

  • Article
  • Open Access

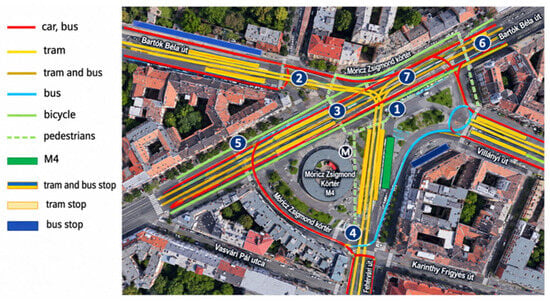
Background: Complex multimodal transport interchanges may impose additional attentional demands on tram drivers, particularly when vulnerable road users unexpectedly enter the tramway. Under persistent stress, time pressure, or passenger-related conflicts, drivers may resort to maladaptive coping strategies to manage internal anxiety. Objective: This exploratory, single-site study examines tram drivers’ self-reported attentional demands and stress at seven preliminarily identified conflict locations at Móricz Zsigmond Square in Budapest and develops site-specific infrastructure recommendations. Methods: The method comprises conflict mapping, a review of available crash records, on-site observations, and two voluntary anonymous questionnaires distributed through an internal tram-driver group. Of an estimated 150 drivers operating routes through the interchange, 32 responded (approximately 21% of this narrowly defined operational community). The first questionnaire used a four-point scale to examine the extent to which tram drivers employ maladaptive coping strategies in their daily work. Its results informed the search for ways to reduce environmental stressors. Subsequently, drivers rated the attentional demands associated with pedestrians, cyclists, e-scooter users, passenger cars, and buses, as well as stress-inducing factors at predefined critical locations, using five-point ordinal scales. Responses were analyzed descriptively. Results: At the four locations examined in detail, pedestrians emerged from drivers’ assessments as the road-user group requiring the greatest additional attention. Accordingly, infrastructure modifications were proposed to support tram drivers. Seven conflict locations were screened initially; the four selected for detailed discussion are presented here. Conclusions: The proposals address pedestrian channelization, coordinated traffic-signal control, visibility and legibility of crossing arrangements, and tram operations. Given the non-probability sample and the unavailability of linked respondent-level observations for inferential testing, the findings are exploratory: neither causal effectiveness nor population-level differences can be established.

Future Transp.

20 November 2026

Conflict map of Móricz Zsigmond Square and the seven preliminarily identified conflict locations.
  • Article
  • Open Access

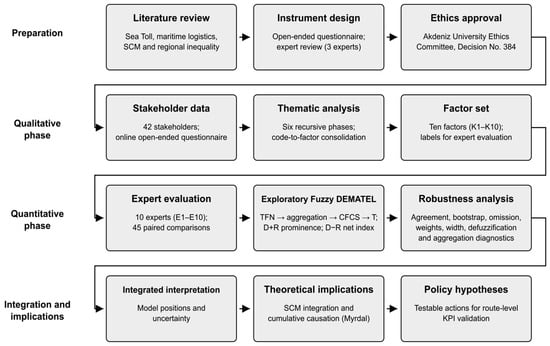
Indonesia’s archipelagic geography creates persistent logistics disparities that the Sea Toll Program has sought to address since 2015. This study integrates stakeholder-derived factor identification with a comparative assessment of expert judgments. Ten factors derived from the responses of 42 stakeholders were evaluated by 10 experts. One-step summaries provide the principal quantitative comparison, with Fuzzy DEMATEL used to explore how higher-order weighting affects the same judgments. K10 (Improving Logistics Activities in Underdeveloped Regions) and K8 (Product Supply and Demand) had the largest positive balances in both summaries, while K1 (Port Infrastructure) had the most negative balance. Descriptive agreement was weak (Kendall’s W = 0.069), and all ten 95% bootstrap intervals for the transformed net indices included zero. Fleet availability (K2) and human resources (K5) occupied boundary positions. Geometric aggregation preserved nine baseline signs but changed prominence rankings. Excluding K9 (Corruption and Transparency) reversed the transformed signs of the two boundary factors, K2 and K5. The study contributes a contextual factor framework and identifies where comparative model results are sensitive to expert composition and analytical choices. It specifies route-level indicators for evaluating literature-informed proposals concerning cargo, connectivity, infrastructure, and information systems, without presenting those proposals as an empirically established intervention sequence.

Future Transp.

19 November 2026

Sequential exploratory research design for the Sea Toll Program. Source: Agustin [60] (Sequential exploratory mixed-methods design adapted from Creswell [59]).
  • Article
  • Open Access

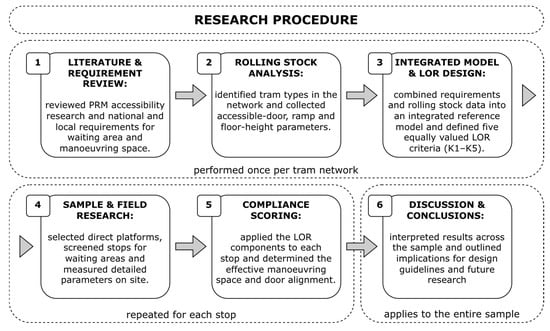
Independent boarding by persons with reduced mobility (PRM) at tram stops requires the waiting position to coincide with the stopping position of the accessible tram doors. This link has rarely been examined. This study assesses PRM waiting areas and manoeuvring space against an integrated standard combining Polish national design guidelines and the local requirements of Wrocław, with the manoeuvring space derived from the door positions of the seven accessible tram models in the fleet. Five criteria (dimensions, location and marking of the waiting area, manoeuvring space and platform edge height) were assessed using the Levels of Compliance with Requirements (LOR) method at 96 stops with direct platforms. No stop met all requirements; the mean LOR value was 0.37. A waiting area was present at 44.8% of the stops; 95.3% of these lay within the manoeuvring space, but only two were at the required position relative to the assumed stopping point. Edge height and manoeuvring space requirements were met considerably better than waiting-area requirements. The national and local requirements proved compatible, and the main gap concerns marking rather than platform geometry. The procedure can be applied to other tram networks once their local requirements and rolling stock are taken into account.

Future Transp.

19 November 2026

Research procedure for assessing waiting areas and manoeuvring space for persons with reduced mobility at tram stops. Source: Authors’ own elaboration.
  • Article
  • Open Access

Network-Aware Cooperative Perception Modeling in the CAVISE Simulation Environment

  • Grigoriy S. Khoroshilov,
  • Evgeny A. Narkhov and
  • Aleksandr Y. Romanov
  • + 2 authors

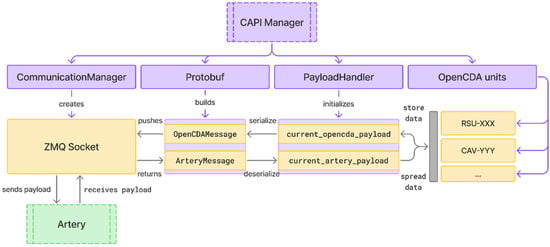
Cooperative perception (CoP) relies on the exchange of sensor data and intermediate perception results between connected and automated vehicles (CAVs) and roadside units (RSUs). Evaluating CoP models therefore requires a simulation environment that combines vehicle dynamics and perception with explicit vehicle-to-everything (V2X) communication models. The CAVISE simulation environment integrates CARLA and OpenCDA with SUMO and Artery for this purpose. Building on earlier CAVISE work, this paper describes the CAVISE API (CAPI), an interface architecture that coordinates bidirectional data exchange between OpenCDA and Artery, synchronized with simulation steps. Its modular message structure supports heterogeneous CoP payloads while preserving transmission outcomes for each agent produced by the network simulator. CAPI is described in the context of the complete CAVISE architecture. Six CoP scenarios are evaluated under three communication configurations: (1) direct exchange without network simulation, (2) Artery using the standard INET propagation model, and (3) Artery using the GEMV2 propagation model. In 4cars_coperception, AP@0.7 changes from 0.214 under direct exchange to 0.094 under INET and 0.097 under GEMV2. Additional cooperative driving automation scenario using an autonomous intersection management model is also evaluated to show the extensibility of CAPI to different CAV applications. Current scalability limitations of the integrated simulation workflow are also identified.

Future Transp.

19 November 2026

CAPI architecture on the OpenCDA side. Purple: CAPI software modules. Yellow: runtime entities and data objects. Green: external simulation component Artery.

Highly Accessed Articles

News & Conferences

Latest Issues

Open for Submission

Journal Sections

XFacebookLinkedIn
Future Transp. - ISSN 2673-7590