Proceeding Paper

The Implementation of a Red Object Tracking Algorithm with a Single, Static Camera †
Department of Electrical Engineering, GIFT University, Gujranwala 52250, Pakistan
*
Authors to whom correspondence should be addressed.
Presented at the 1st International Conference on Energy, Power and Environment, Gujrat, Pakistan, 11–12 November 2021.
Eng. Proc. 2021, 12(1), 40; https://doi.org/10.3390/engproc2021012040

Published: 28 December 2021
(This article belongs to the Proceedings of The 1st International Conference on Energy, Power and Environment)

Abstract

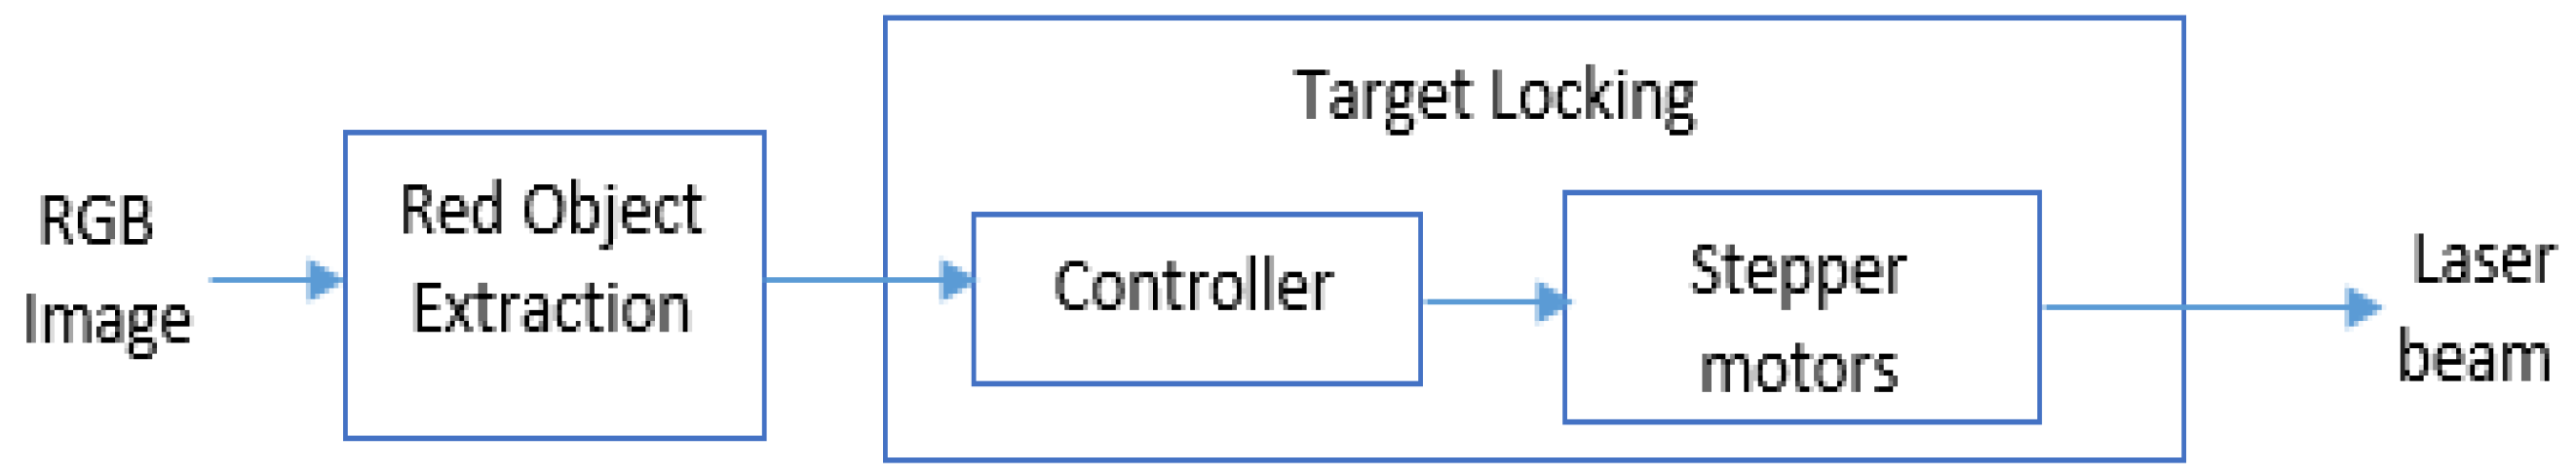
In recent years, activity recognition and object tracking are receiving extensive attention due to the increasing demand for adaptable surveillance systems. Activity recognition is guided by the parameters such as the shape, size, and color of the object. This article purposes an examination of the performance of existing color-based object detection and tracking algorithms using thermal/visual camera-based video steaming in MATLAB. A framework is developed to detect and track red moving objects in real time. Detection is carried out based on the location information acquired from an adaptive image processing algorithm. Coordinate extraction is followed by tracking and locking the object with the help of a laser barrel. The movement of the laser barrel is controlled with the help of an 8051 microcontroller. Location information is communicated from the image-processing algorithm to the microcontroller serially. During implementation, a single static camera is used that provides 30 frames per second. For each frame, 88 ms are required to complete all three steps from detection to tracking, to locking, so a processing speed of 12 frames per second is implemented. This repetition makes the setup adaptive to the environment despite the presence of a single static camera. This setup can handle multiple objects with shades of red and has demonstrated equally good results in varying outdoor conditions. Currently, the setup can lock only single targets, but the capacity of the system can be increased with the installation of multiple cameras and laser barrels.
Keywords: image processing; frames per second; Matlab; object detection image processing; frames per second; Matlab; object detection