

Design and Verification of 6-DOF Robotic Arm for Captive Trajectory System Applications in Wind Tunnel

 ,
 , ,

Abstract
1. Introduction
1.1. Problem Statement and Motivation
1.2. Research Gap
1.3. Purpose of the Experiment
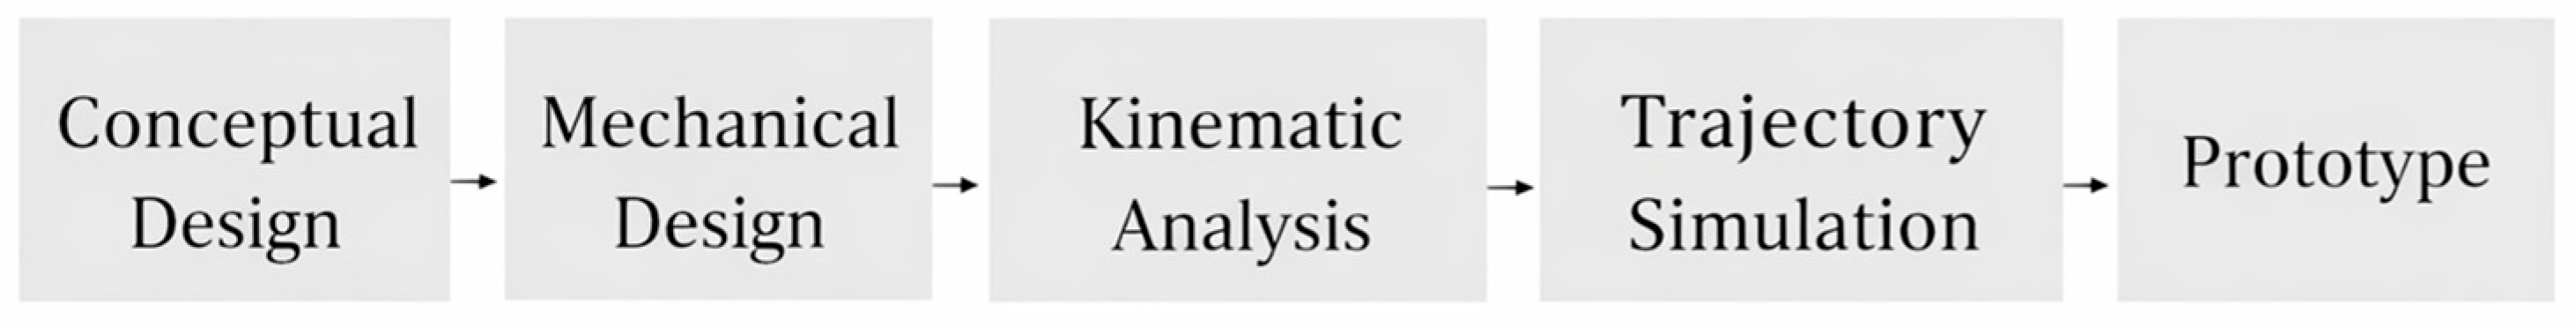
- RQ1: Can a 6-DOF robotic manipulator be kinematically designed by using closed-form forward and inverse kinematics in order to satisfy the workspace and motion related requirements of CTS?
- RQ2: Can the derived kinematic model accurately track experimentally obtained 6-DOF store separation trajectories in a simulation environment?
- RQ3: Can the same kinematic framework be implemented on a physical prototype and reasonable trajectory tracking performance is demonstrated under practical hardware constraints?
2. Related Work and Background
3. Materials and Methods
3.1. Sample Trajectory
3.2. Kinematics Modeling of 6-DOF Manipulator
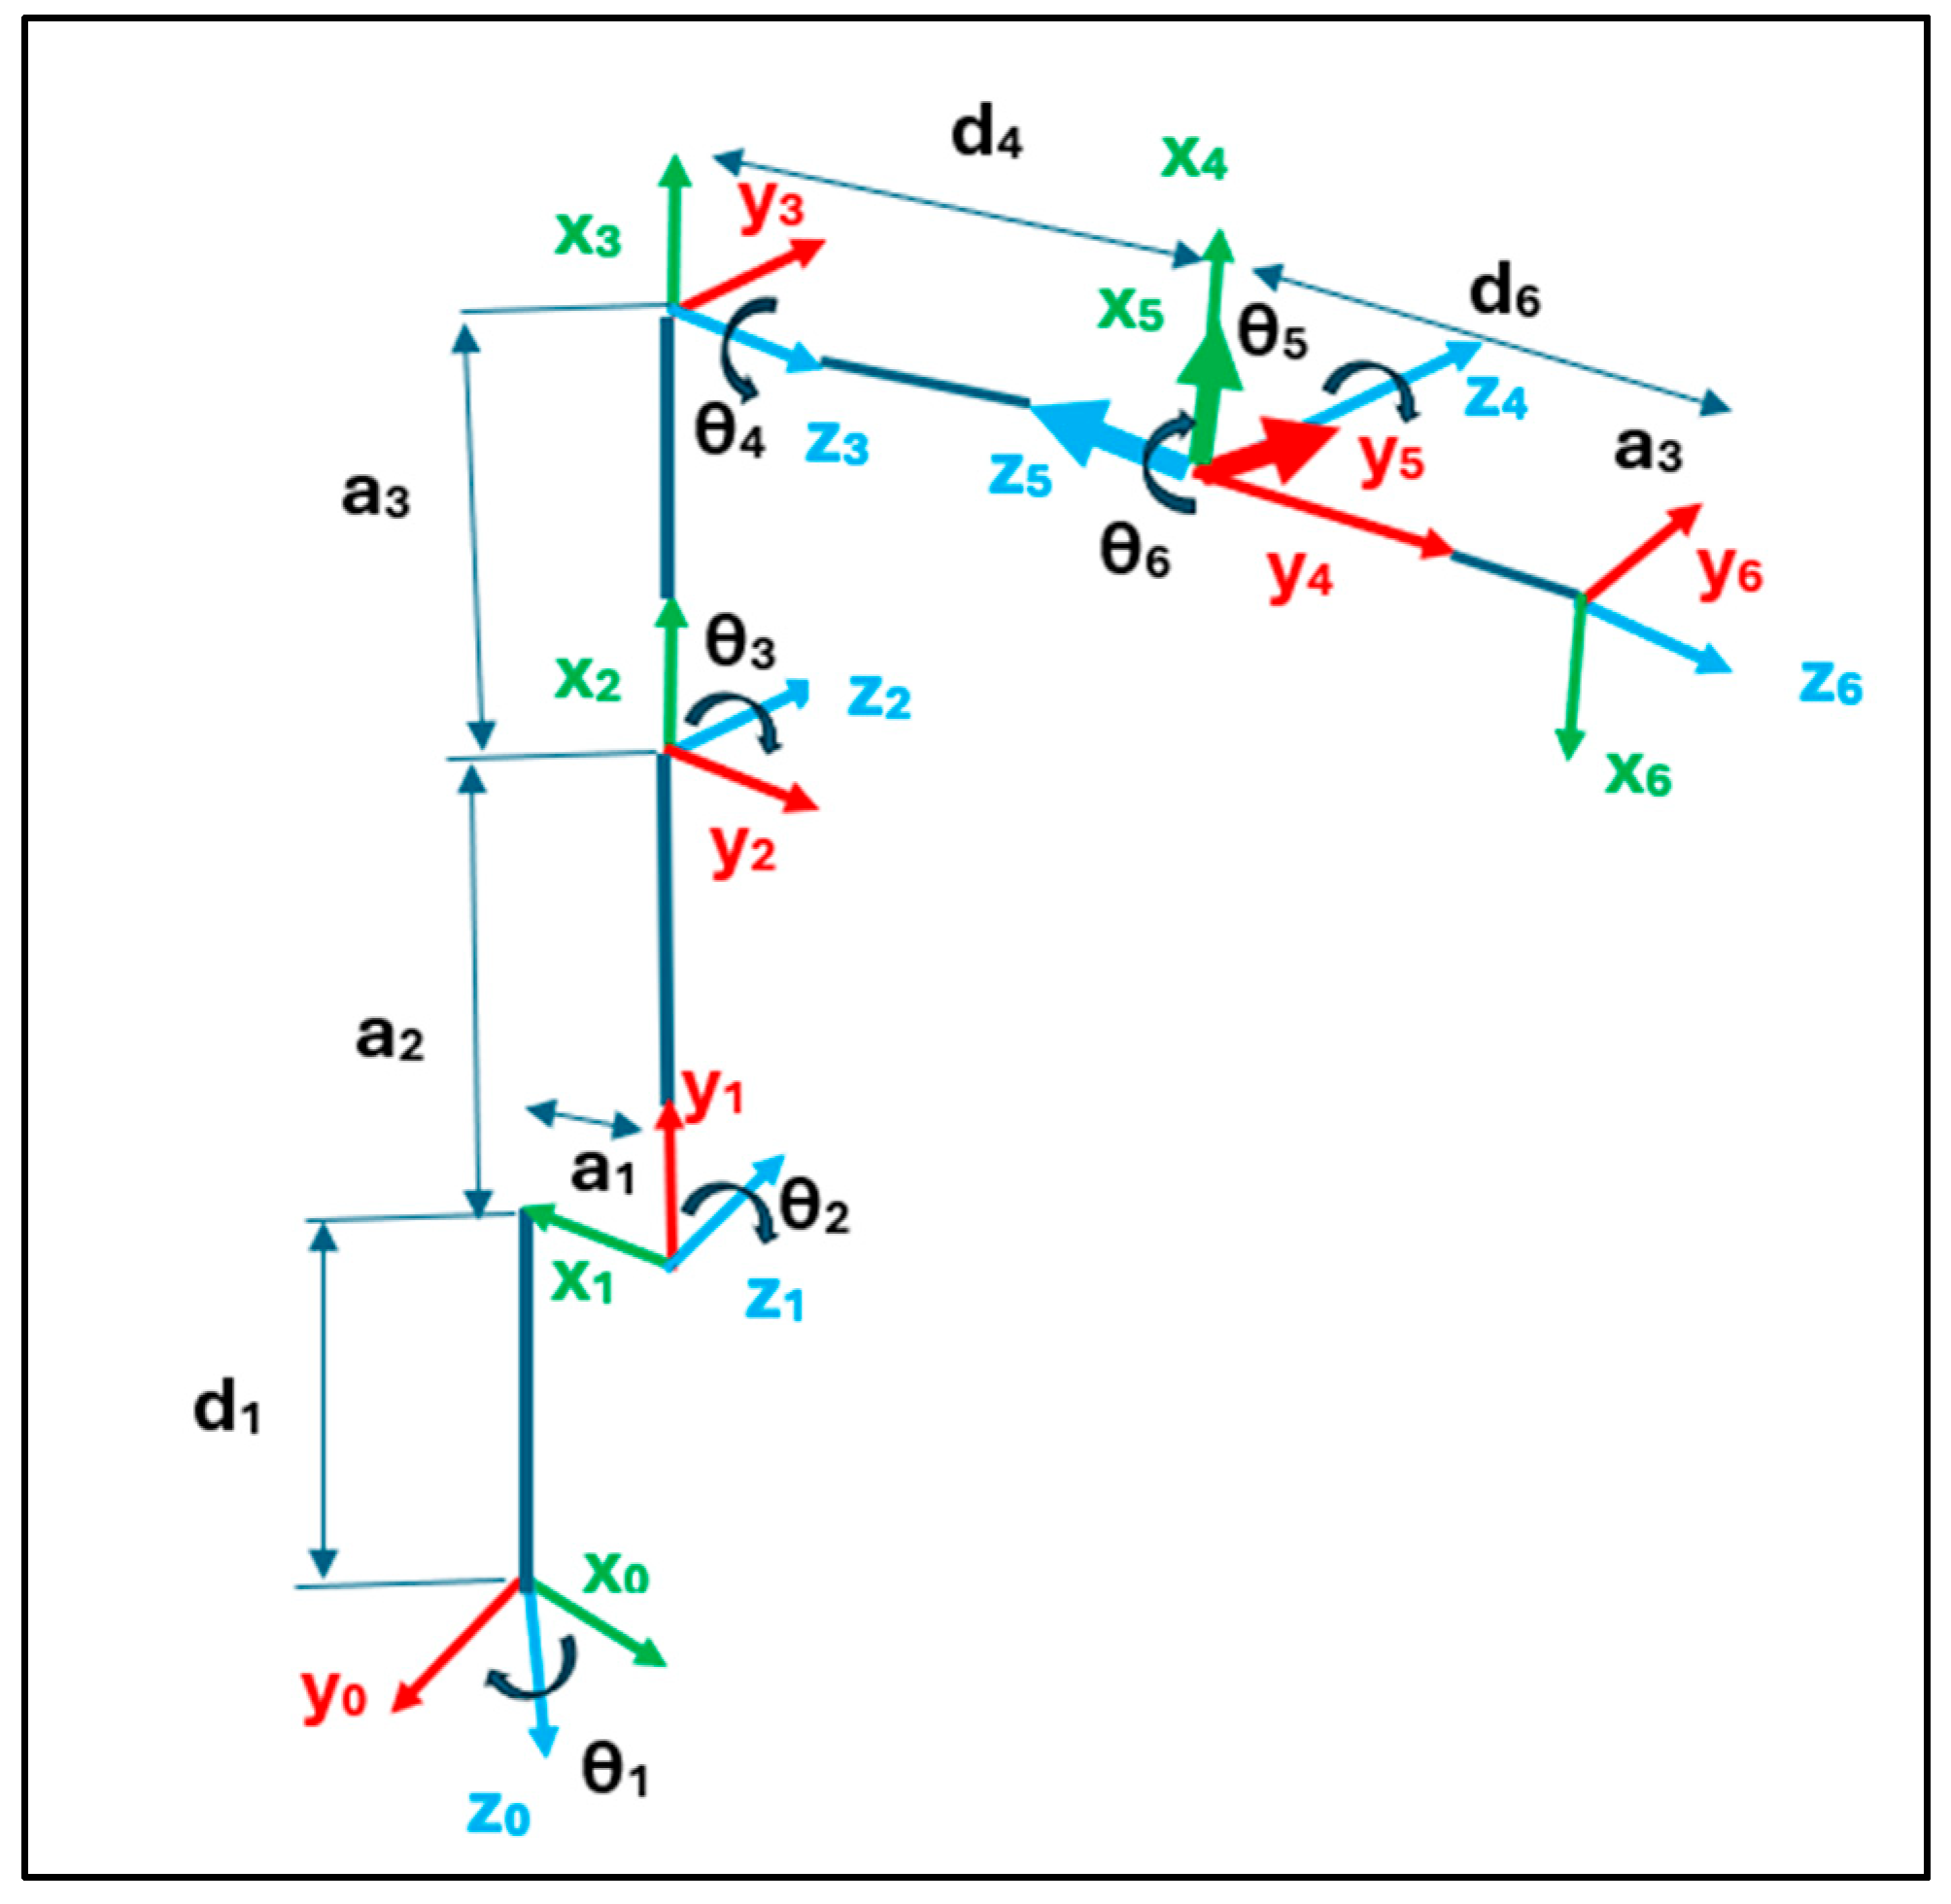
3.2.1. Forward Kinematics Analysis Using Denavit–Hartenberg (DH) Convention
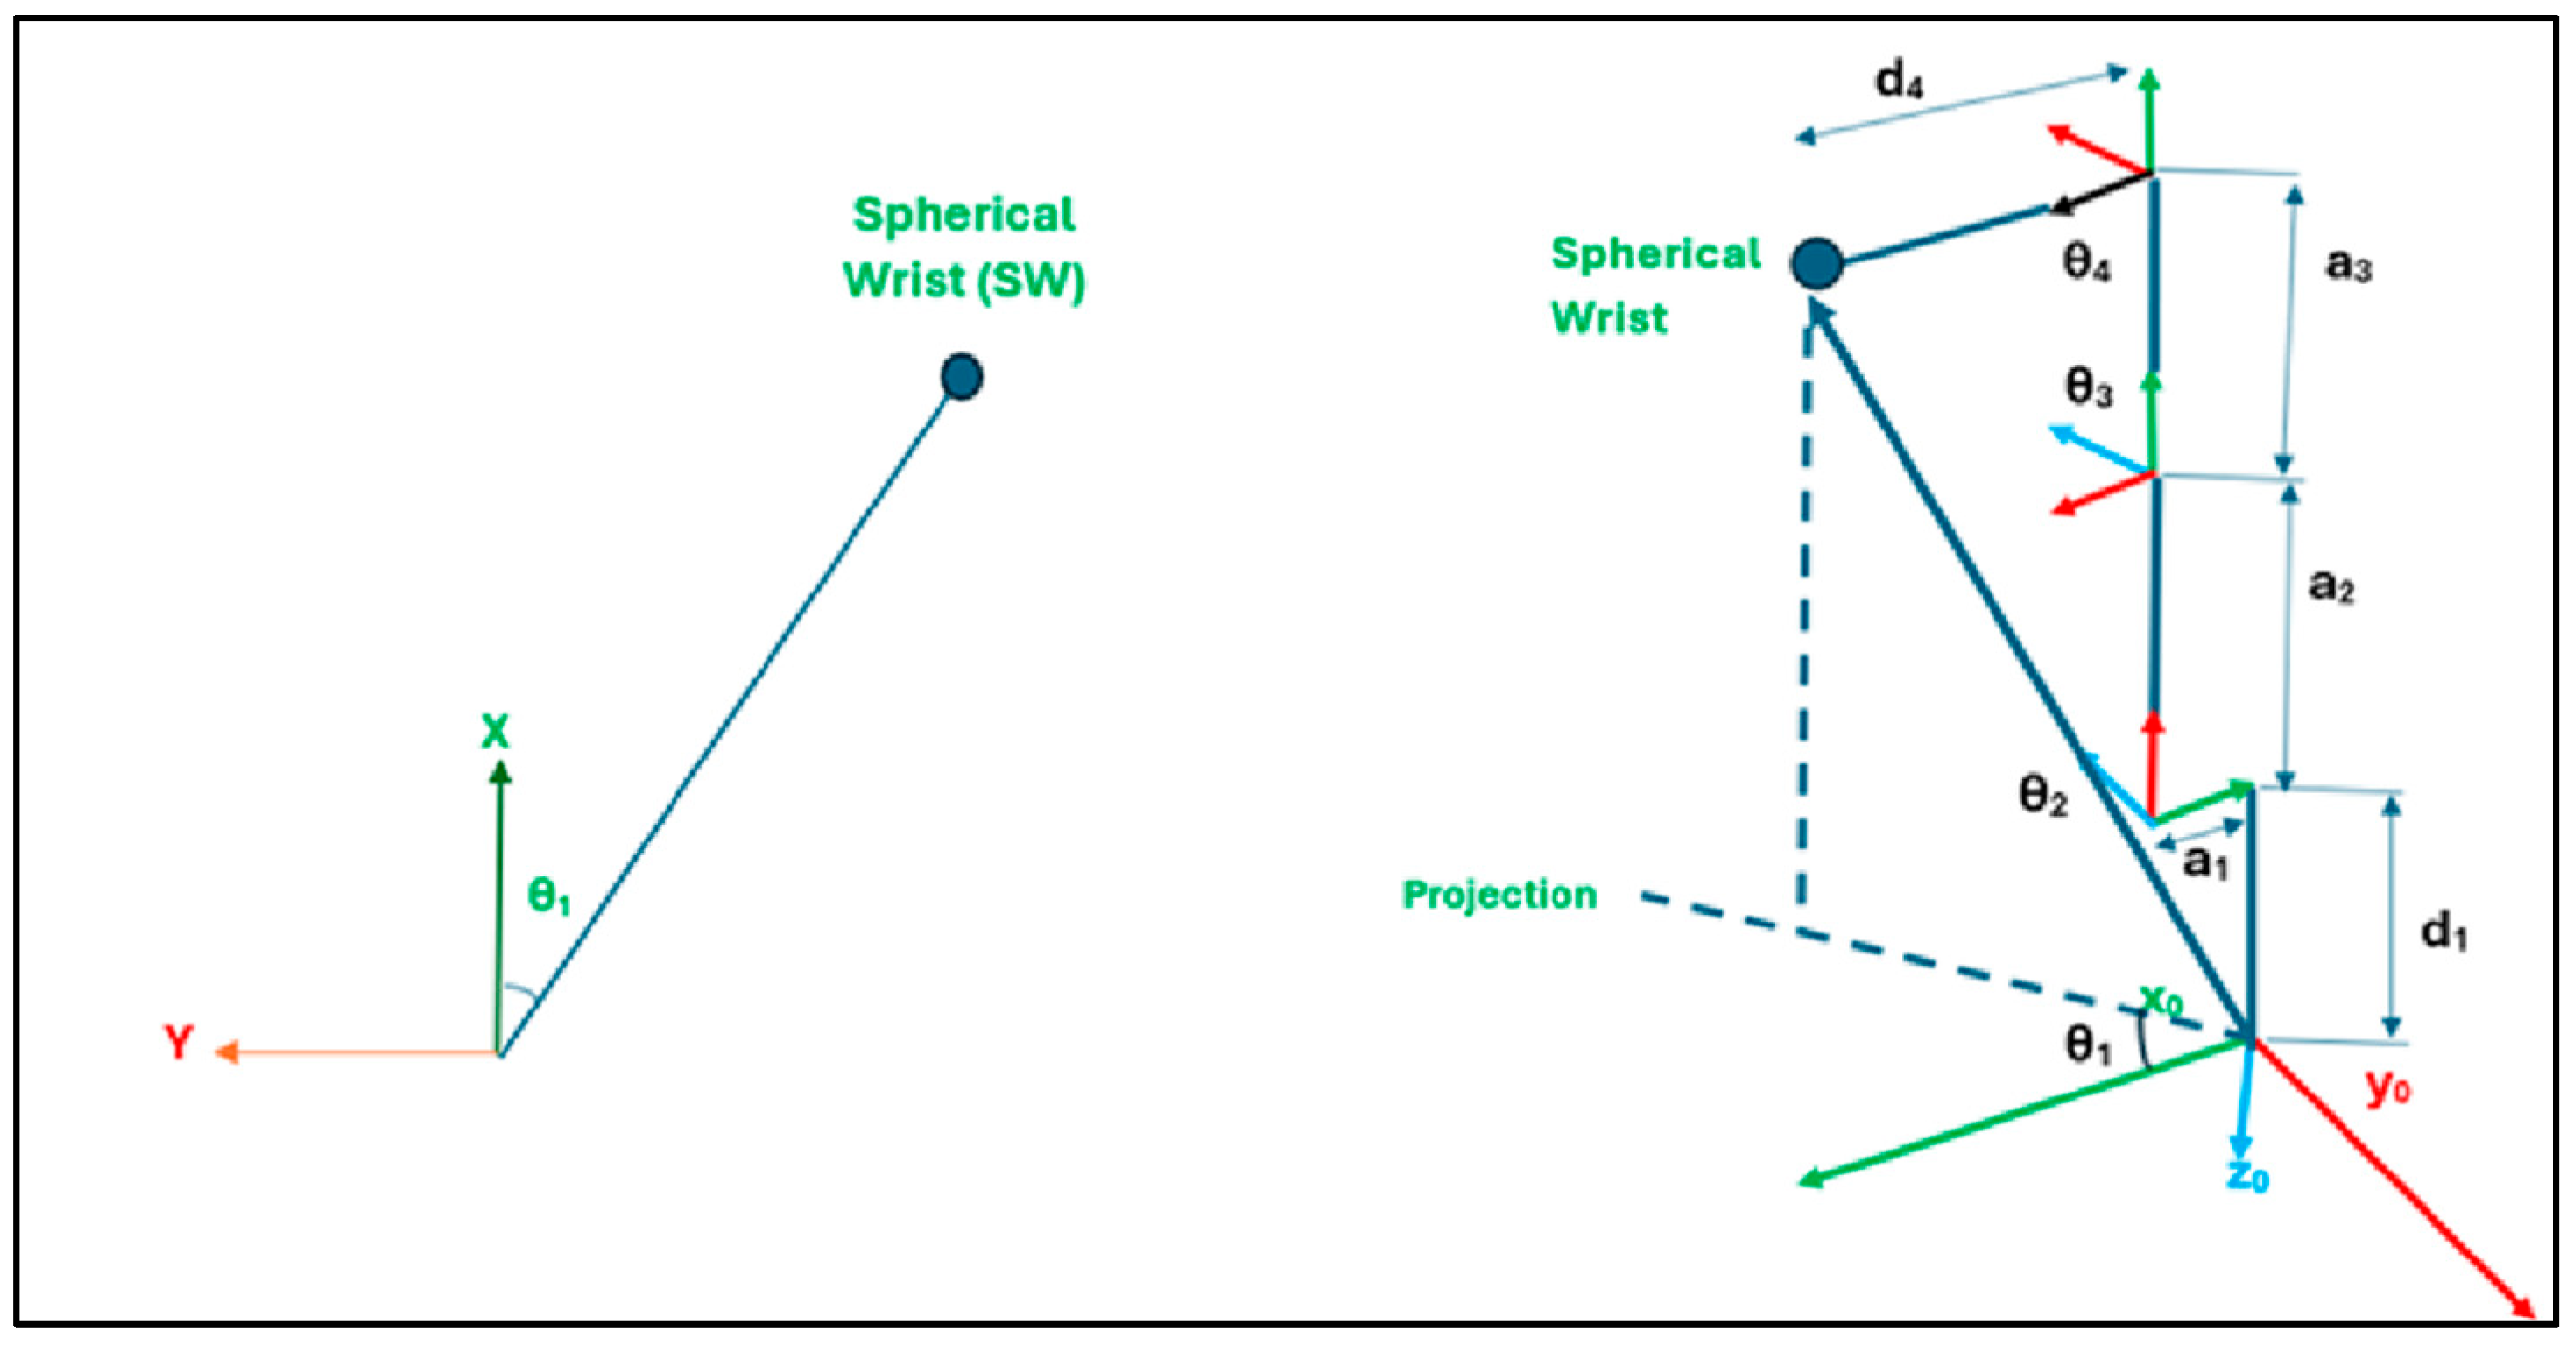
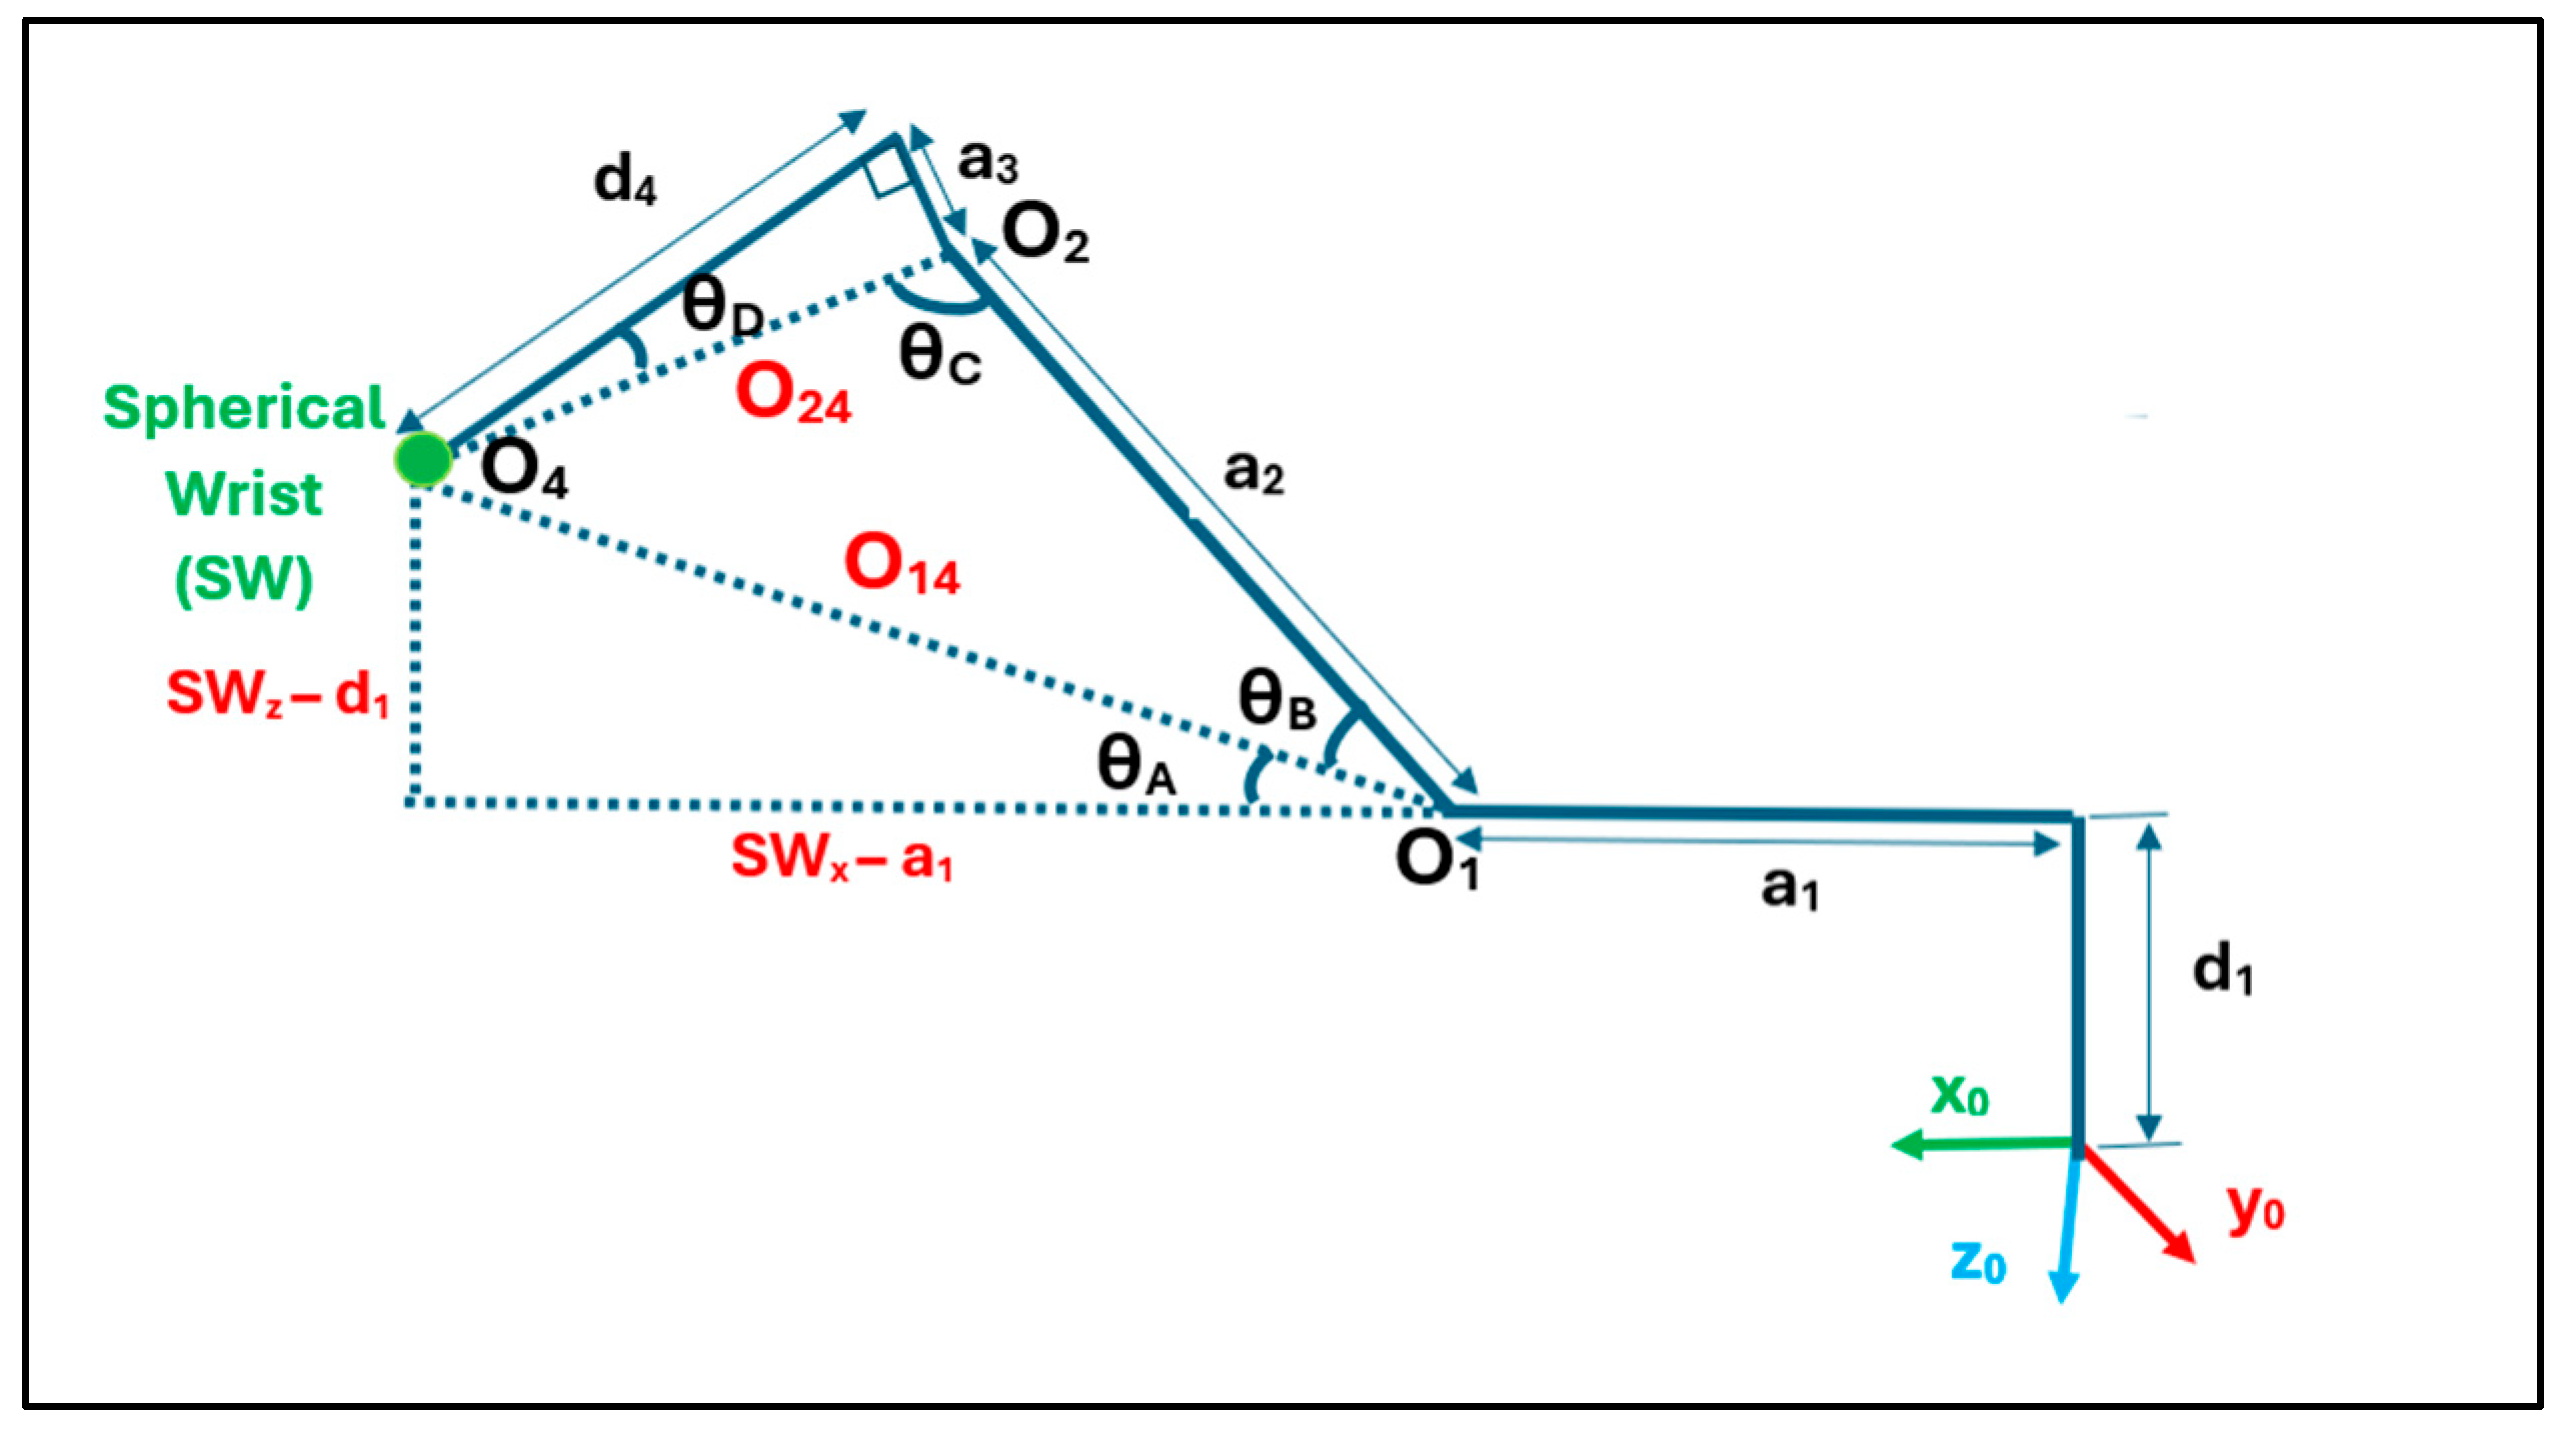
3.2.2. Inverse Kinematics Analysis
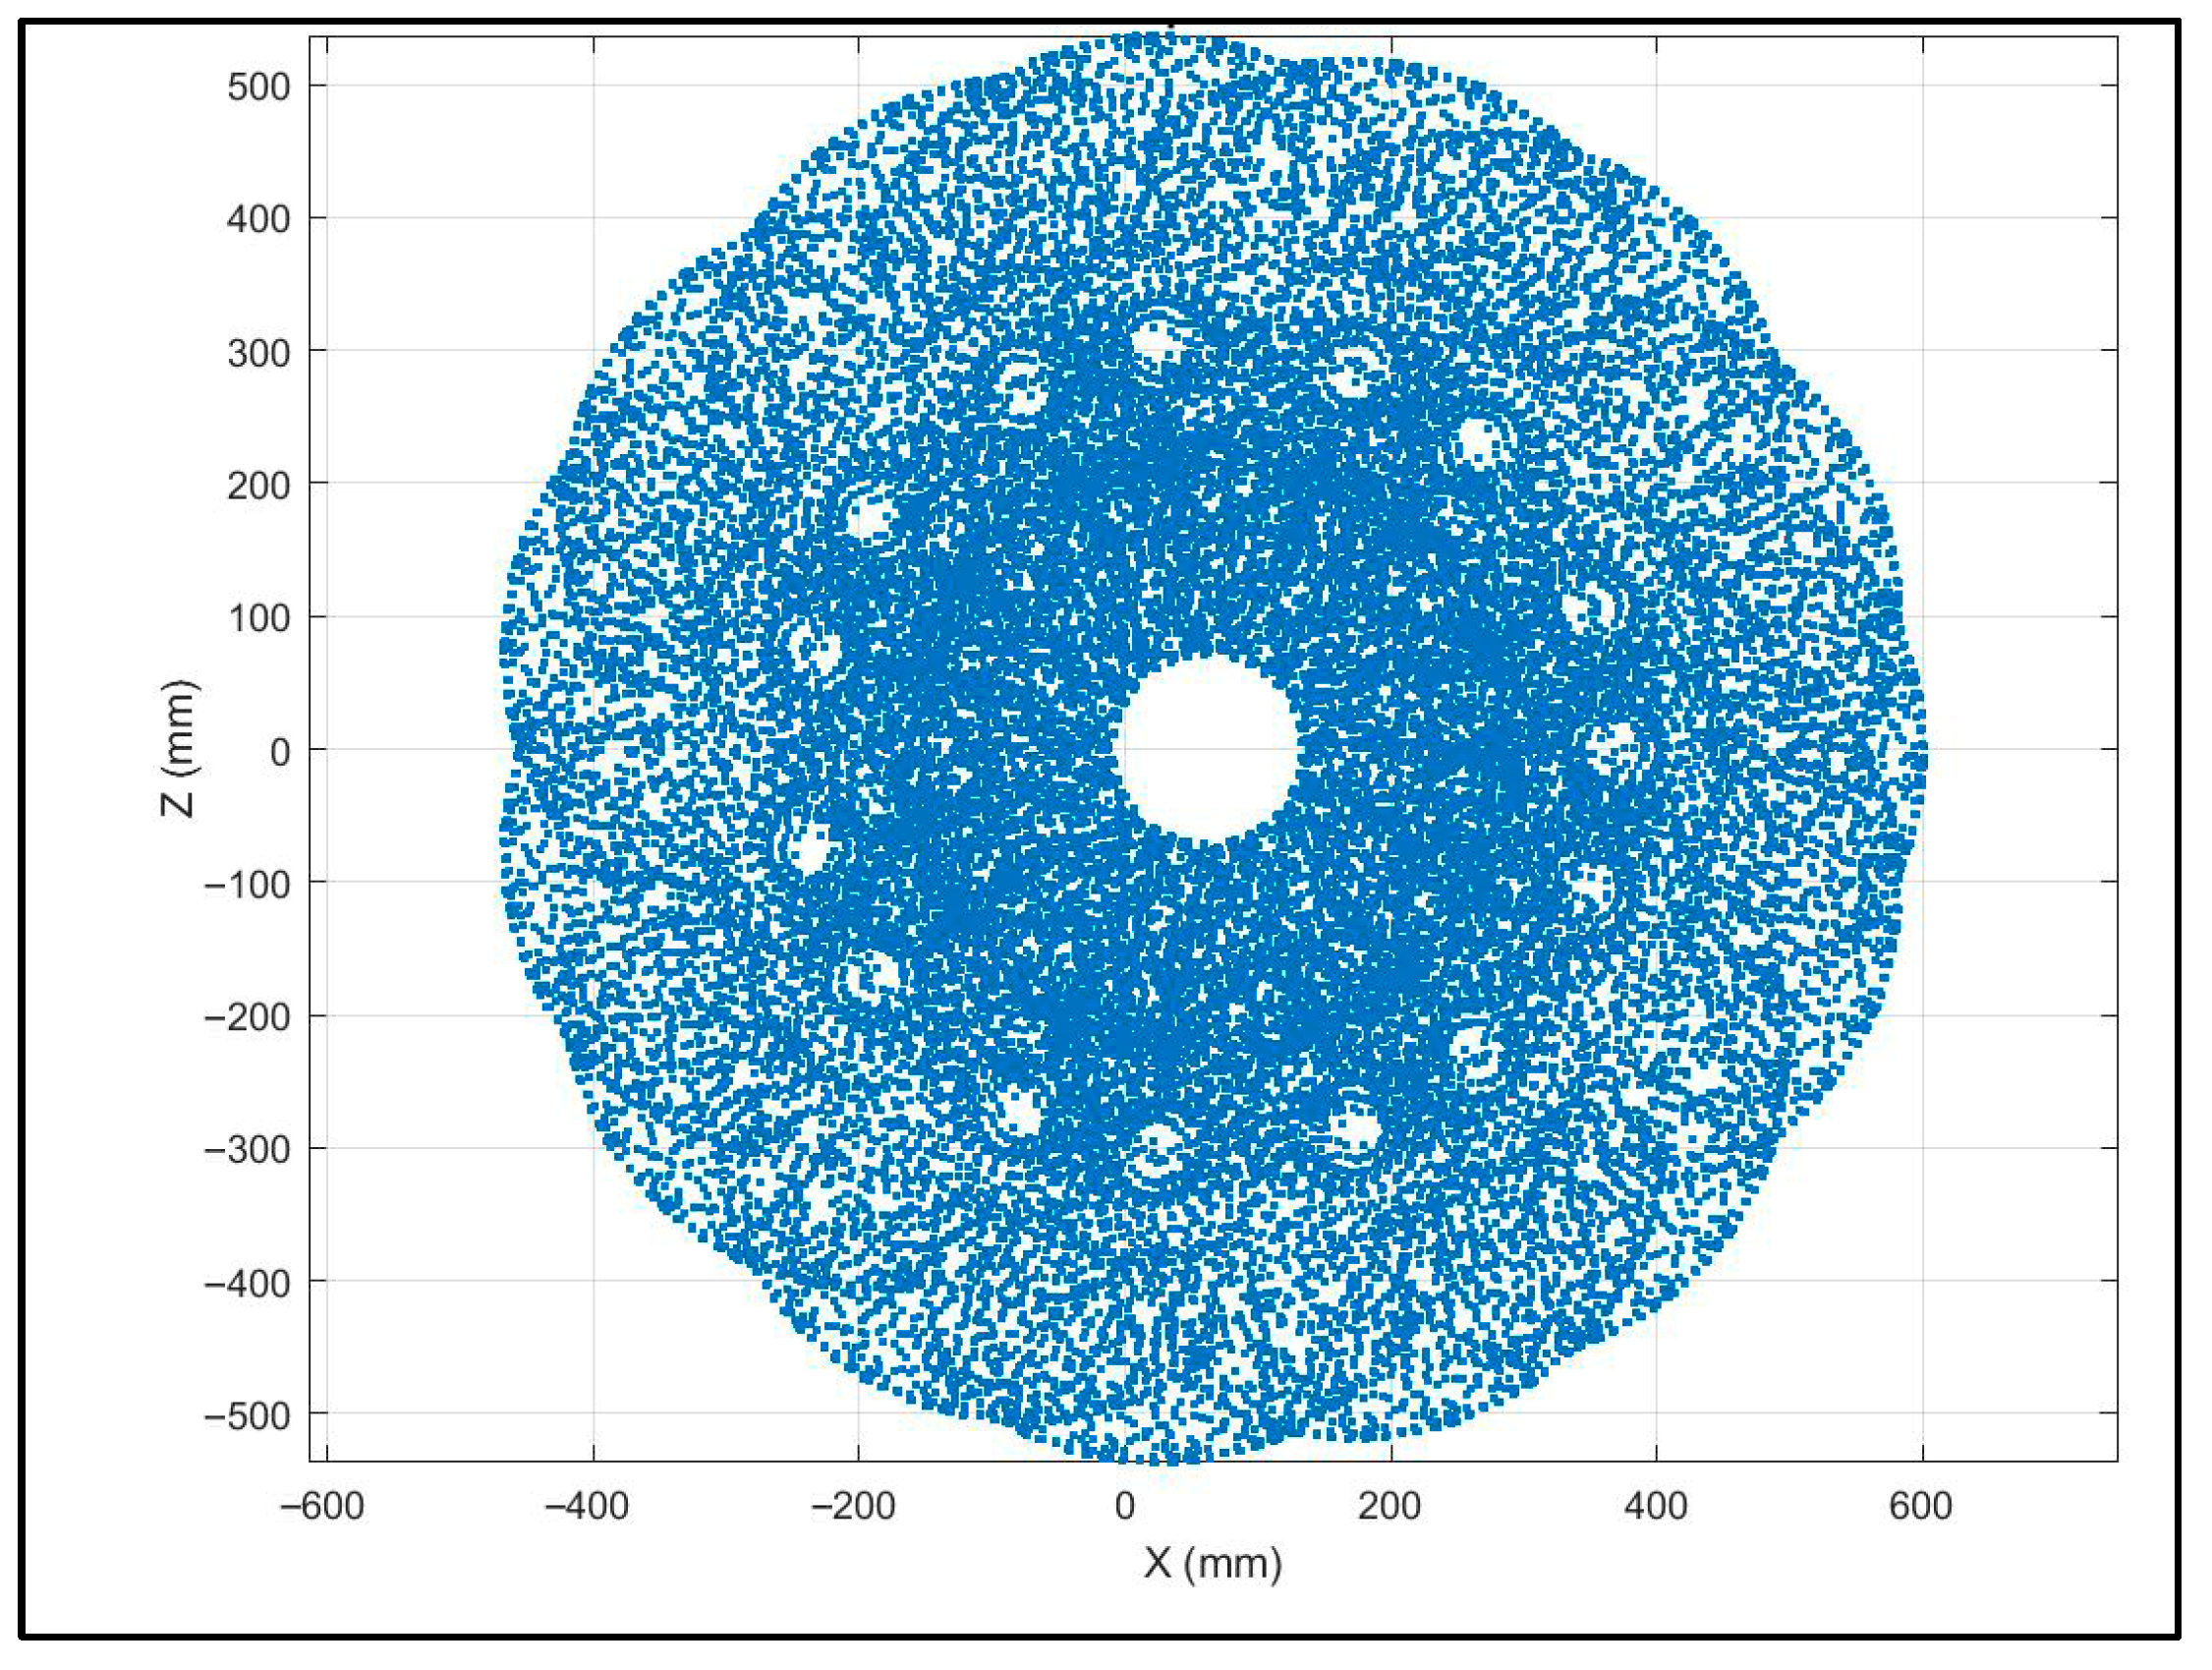
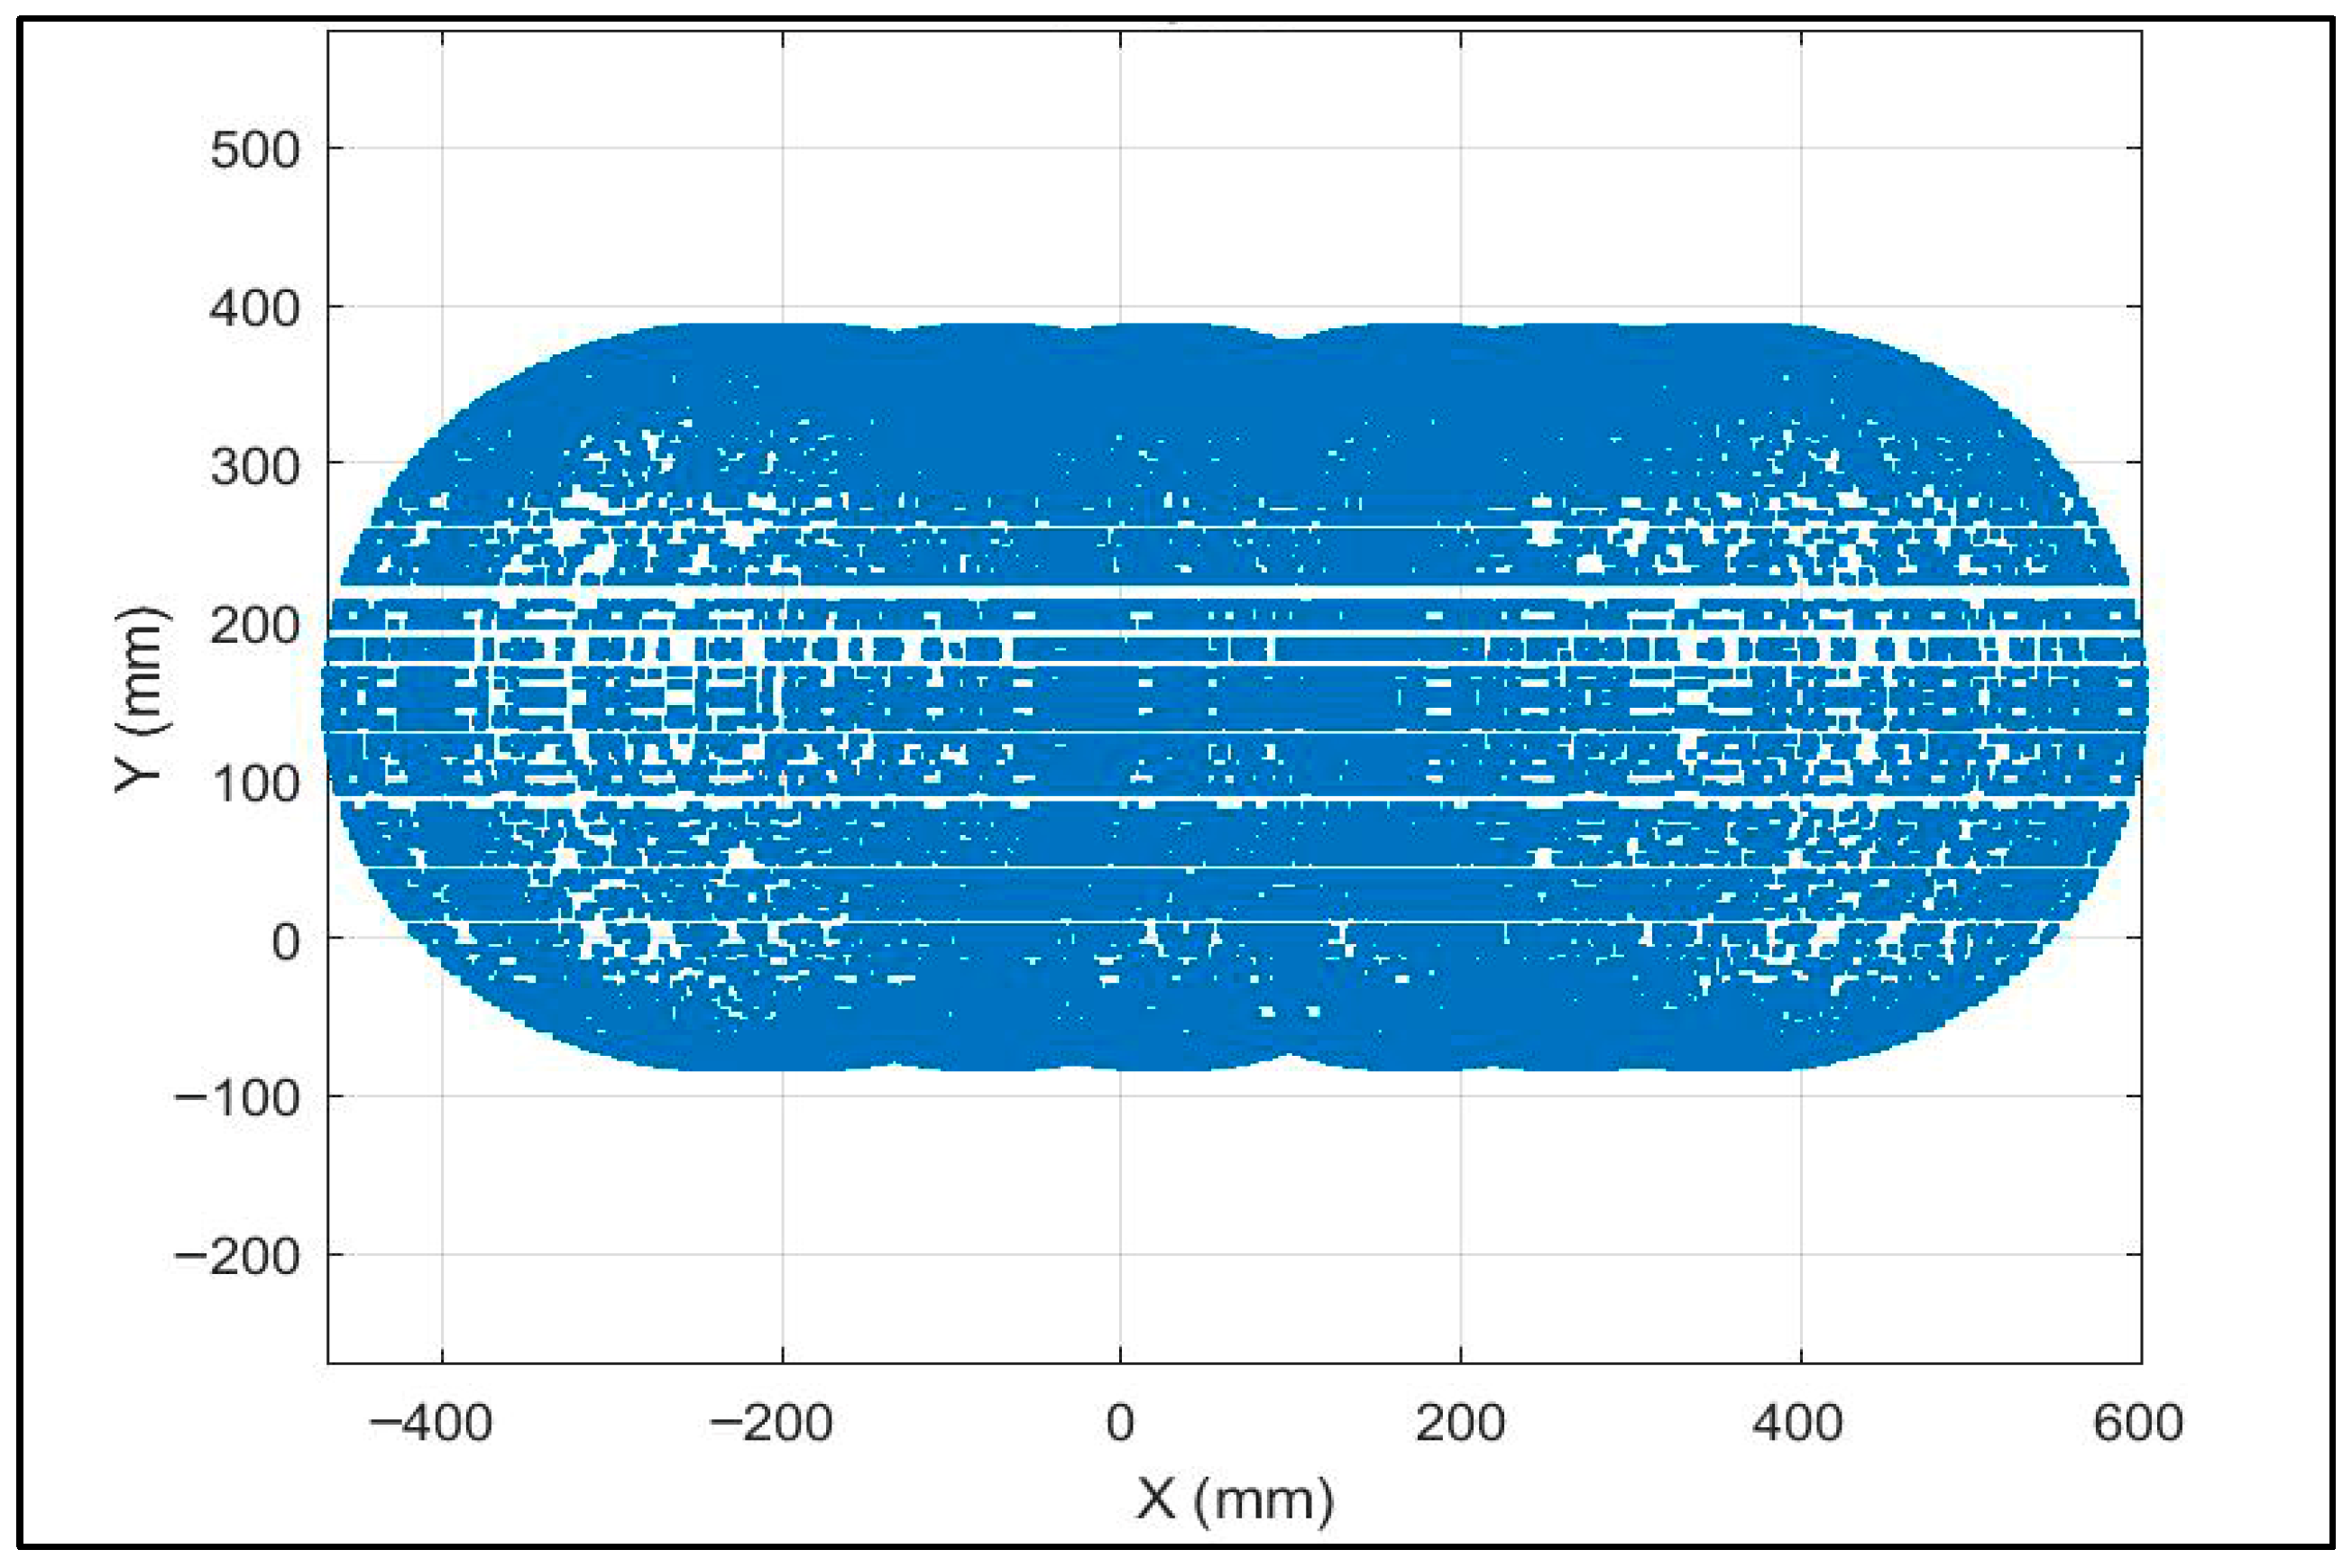
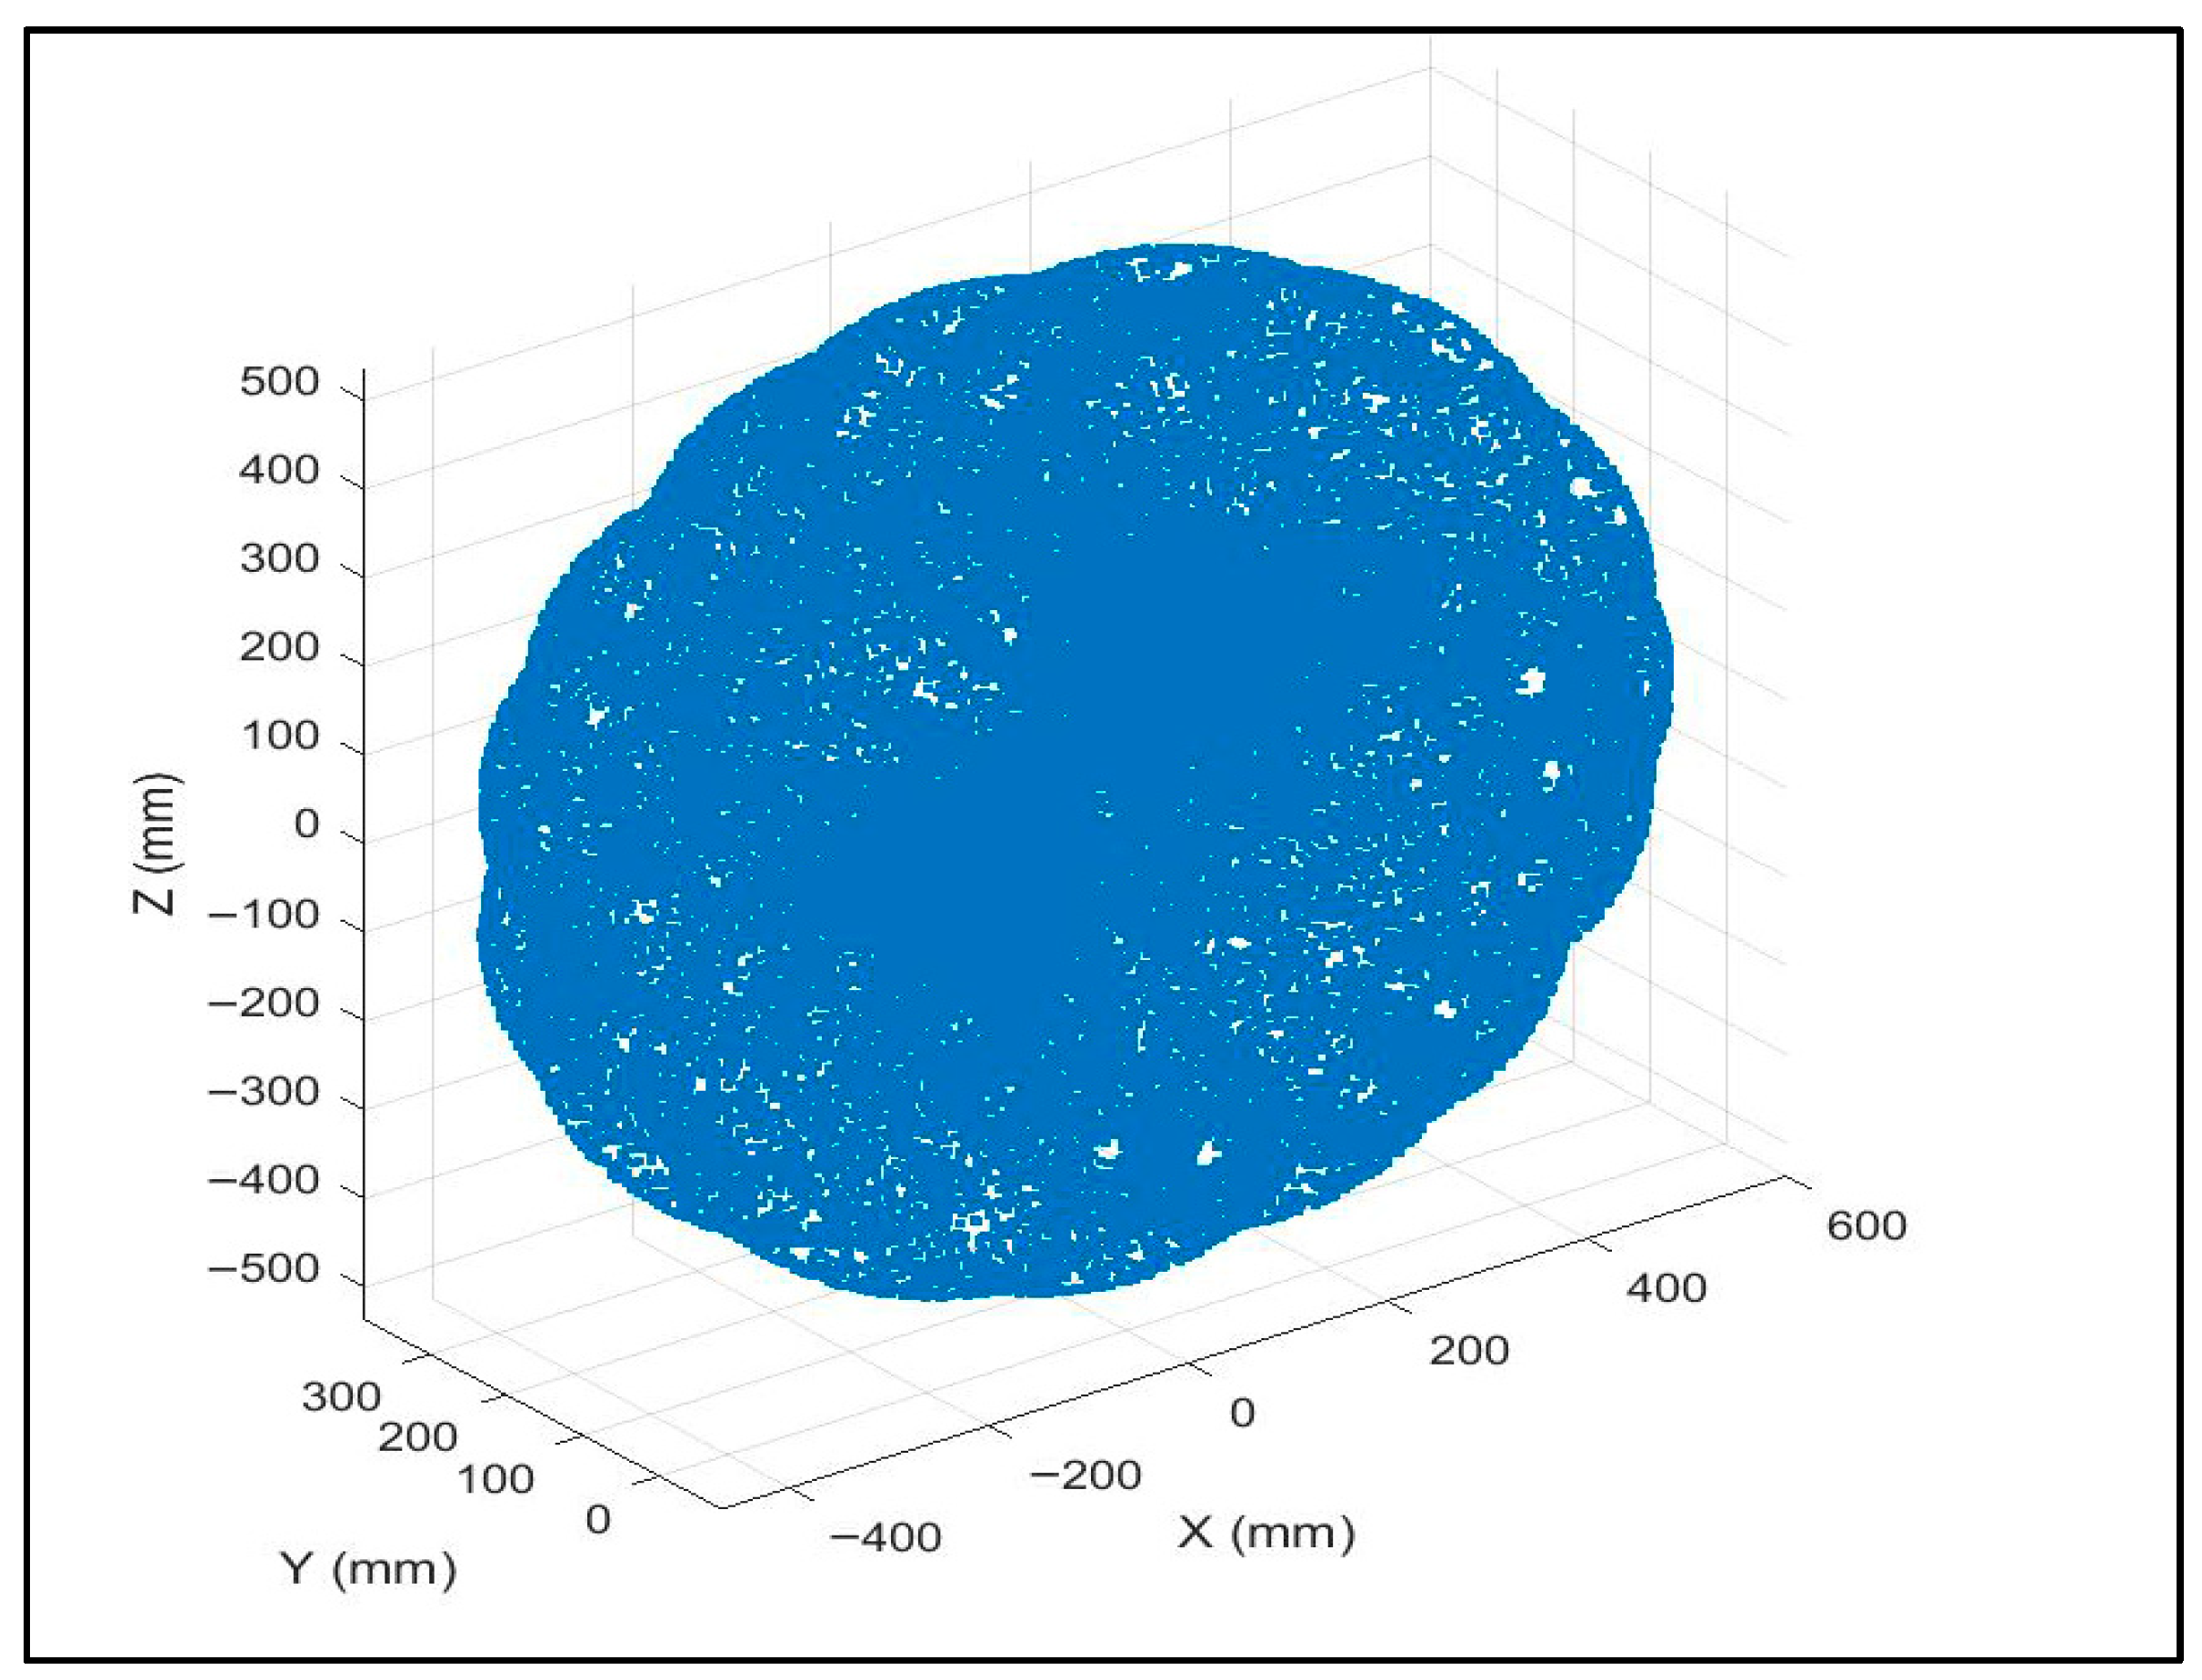
3.3. Workspace Analysis
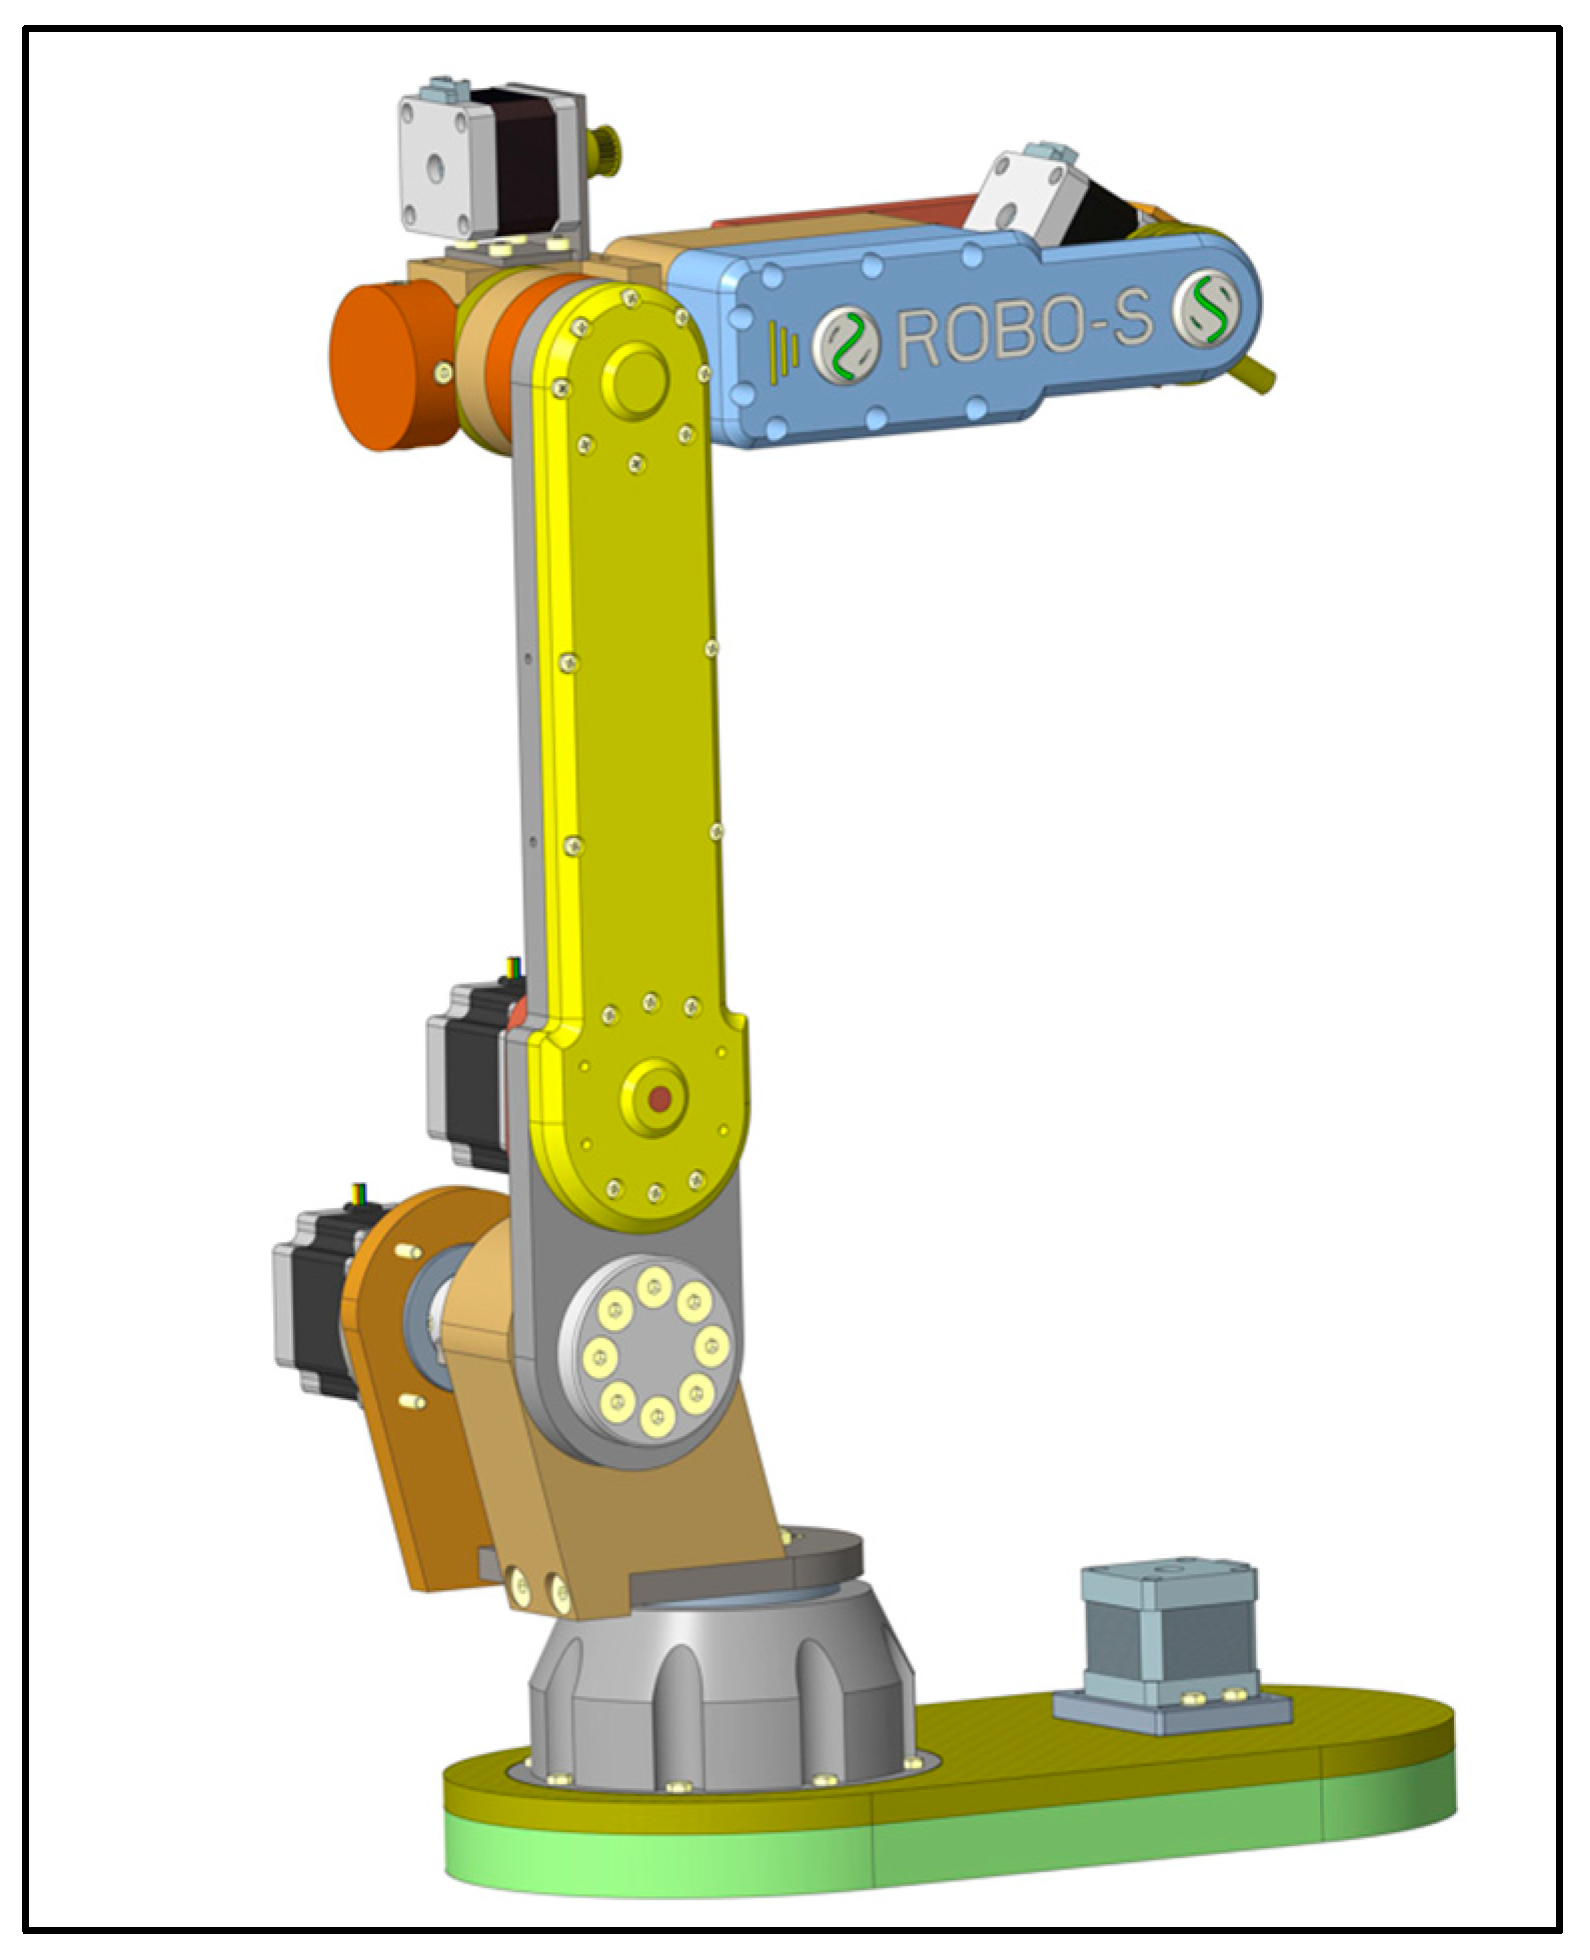
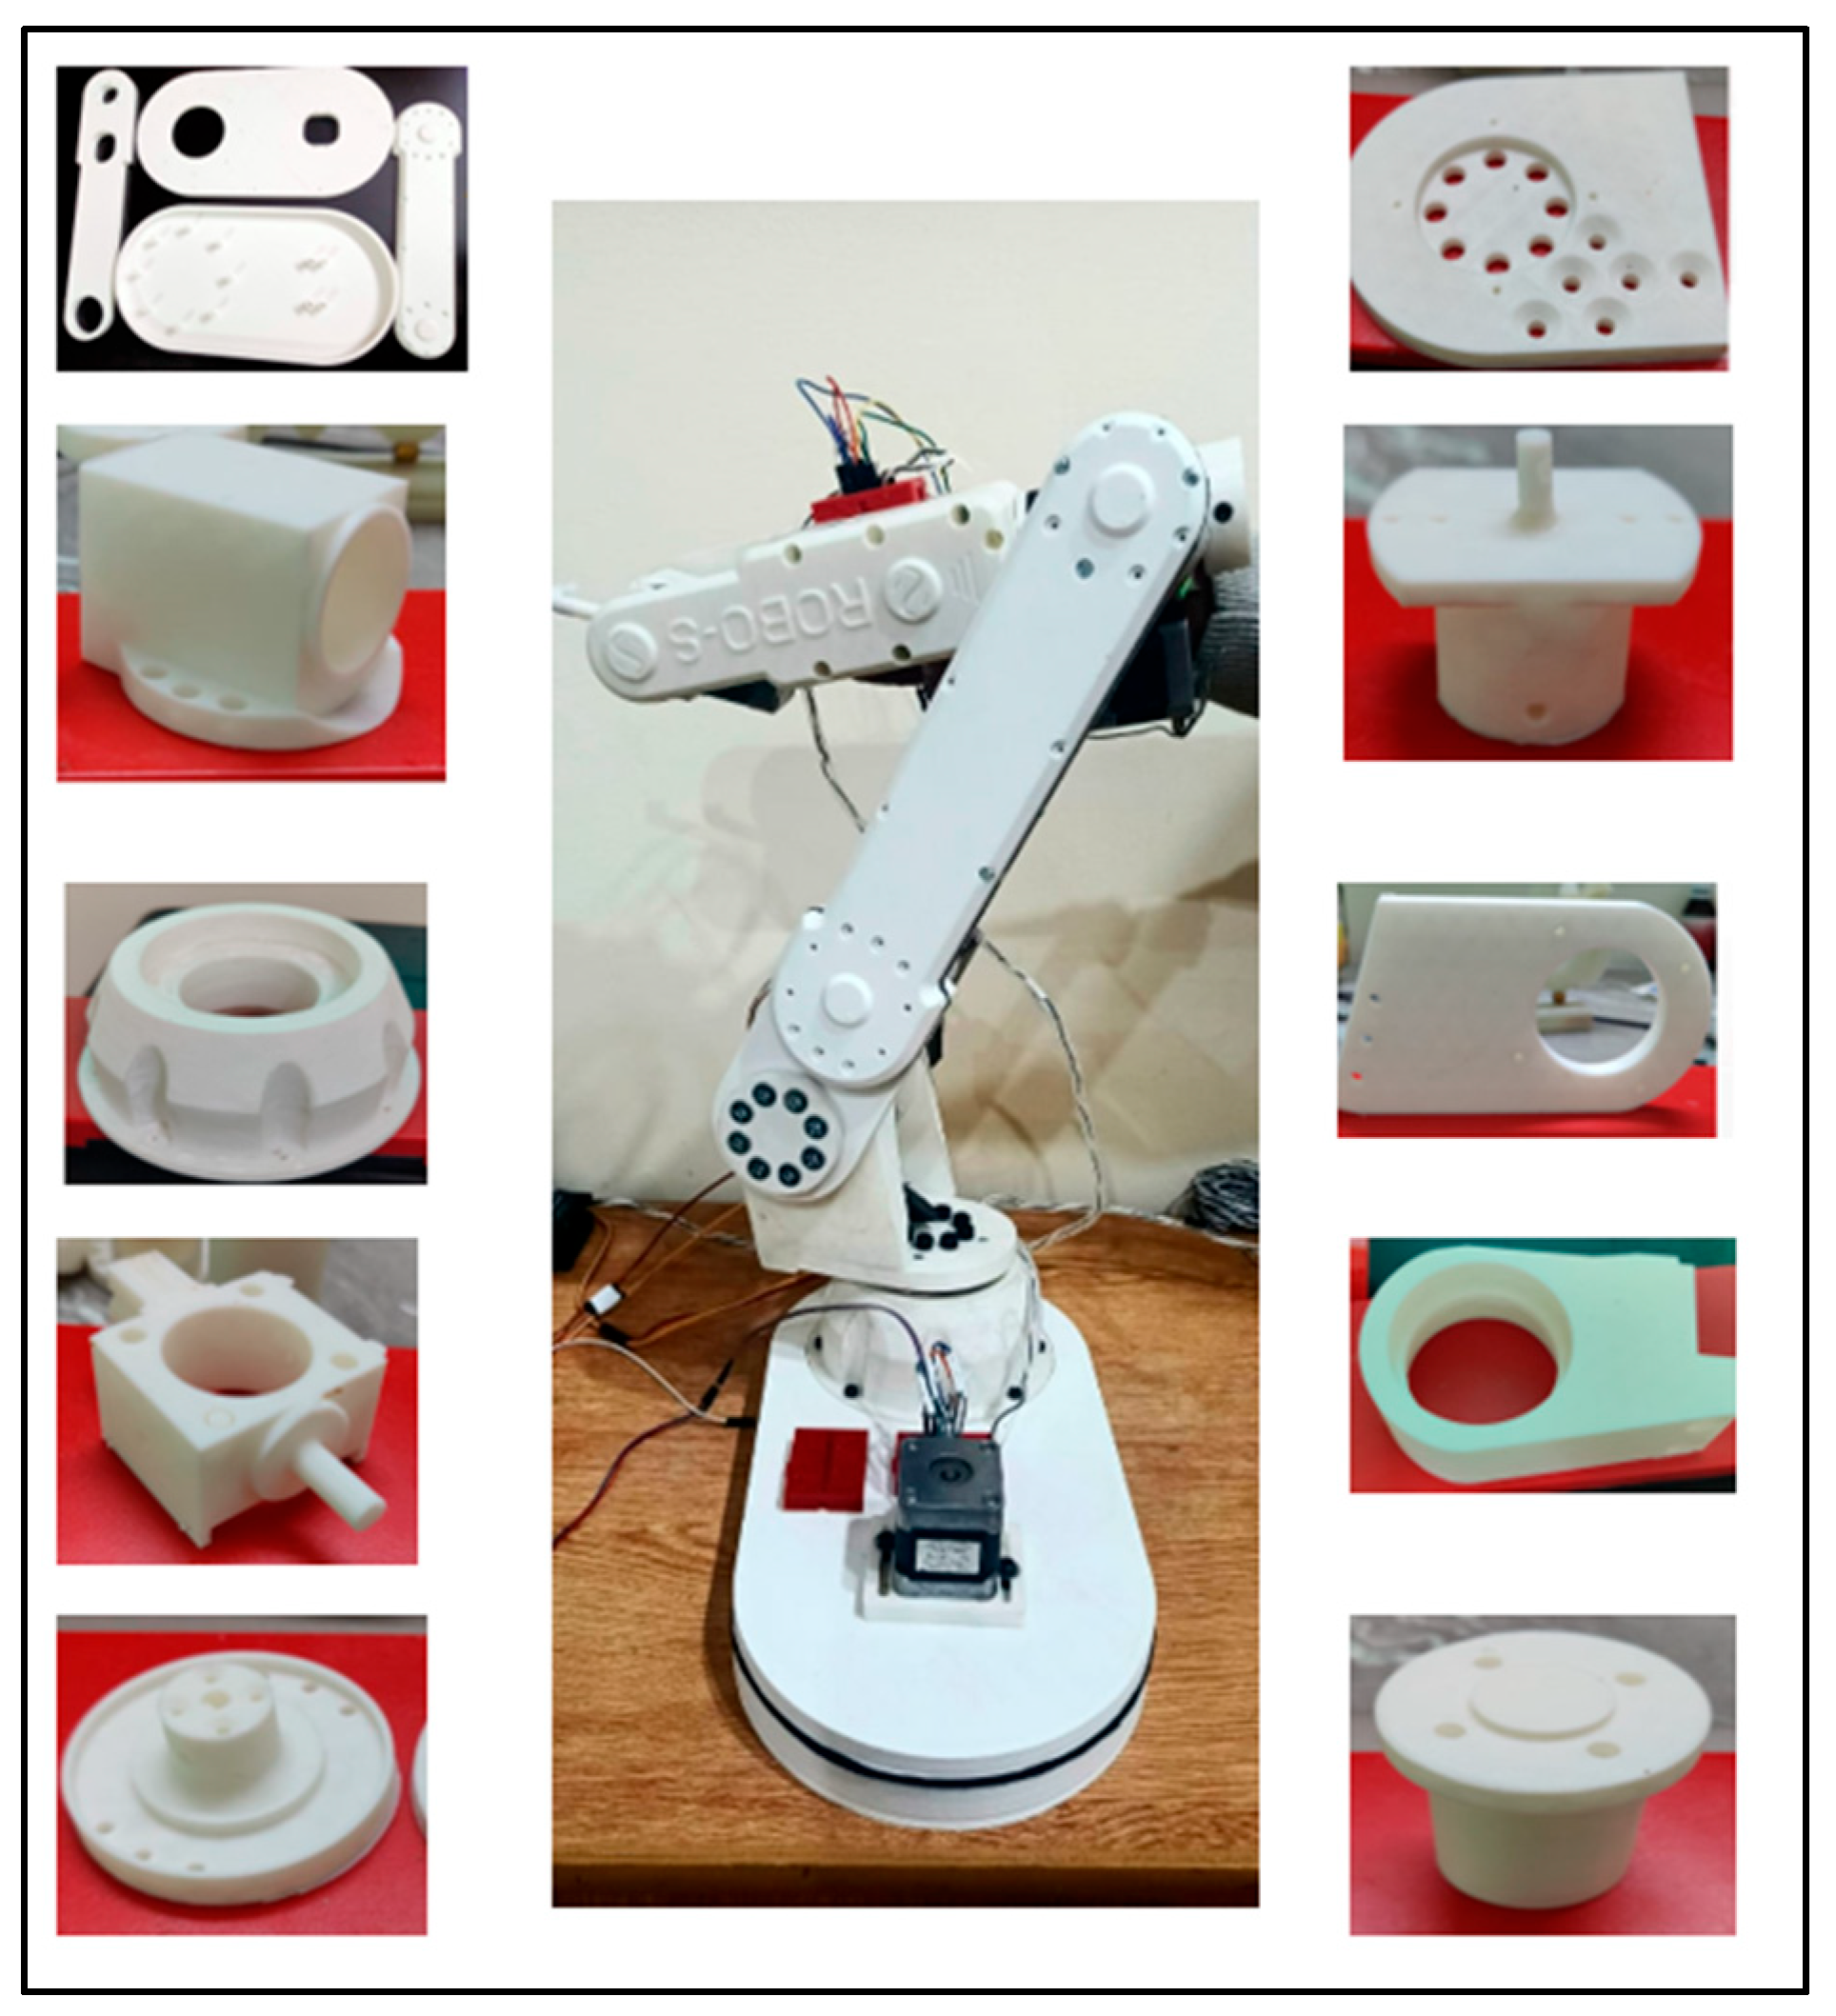
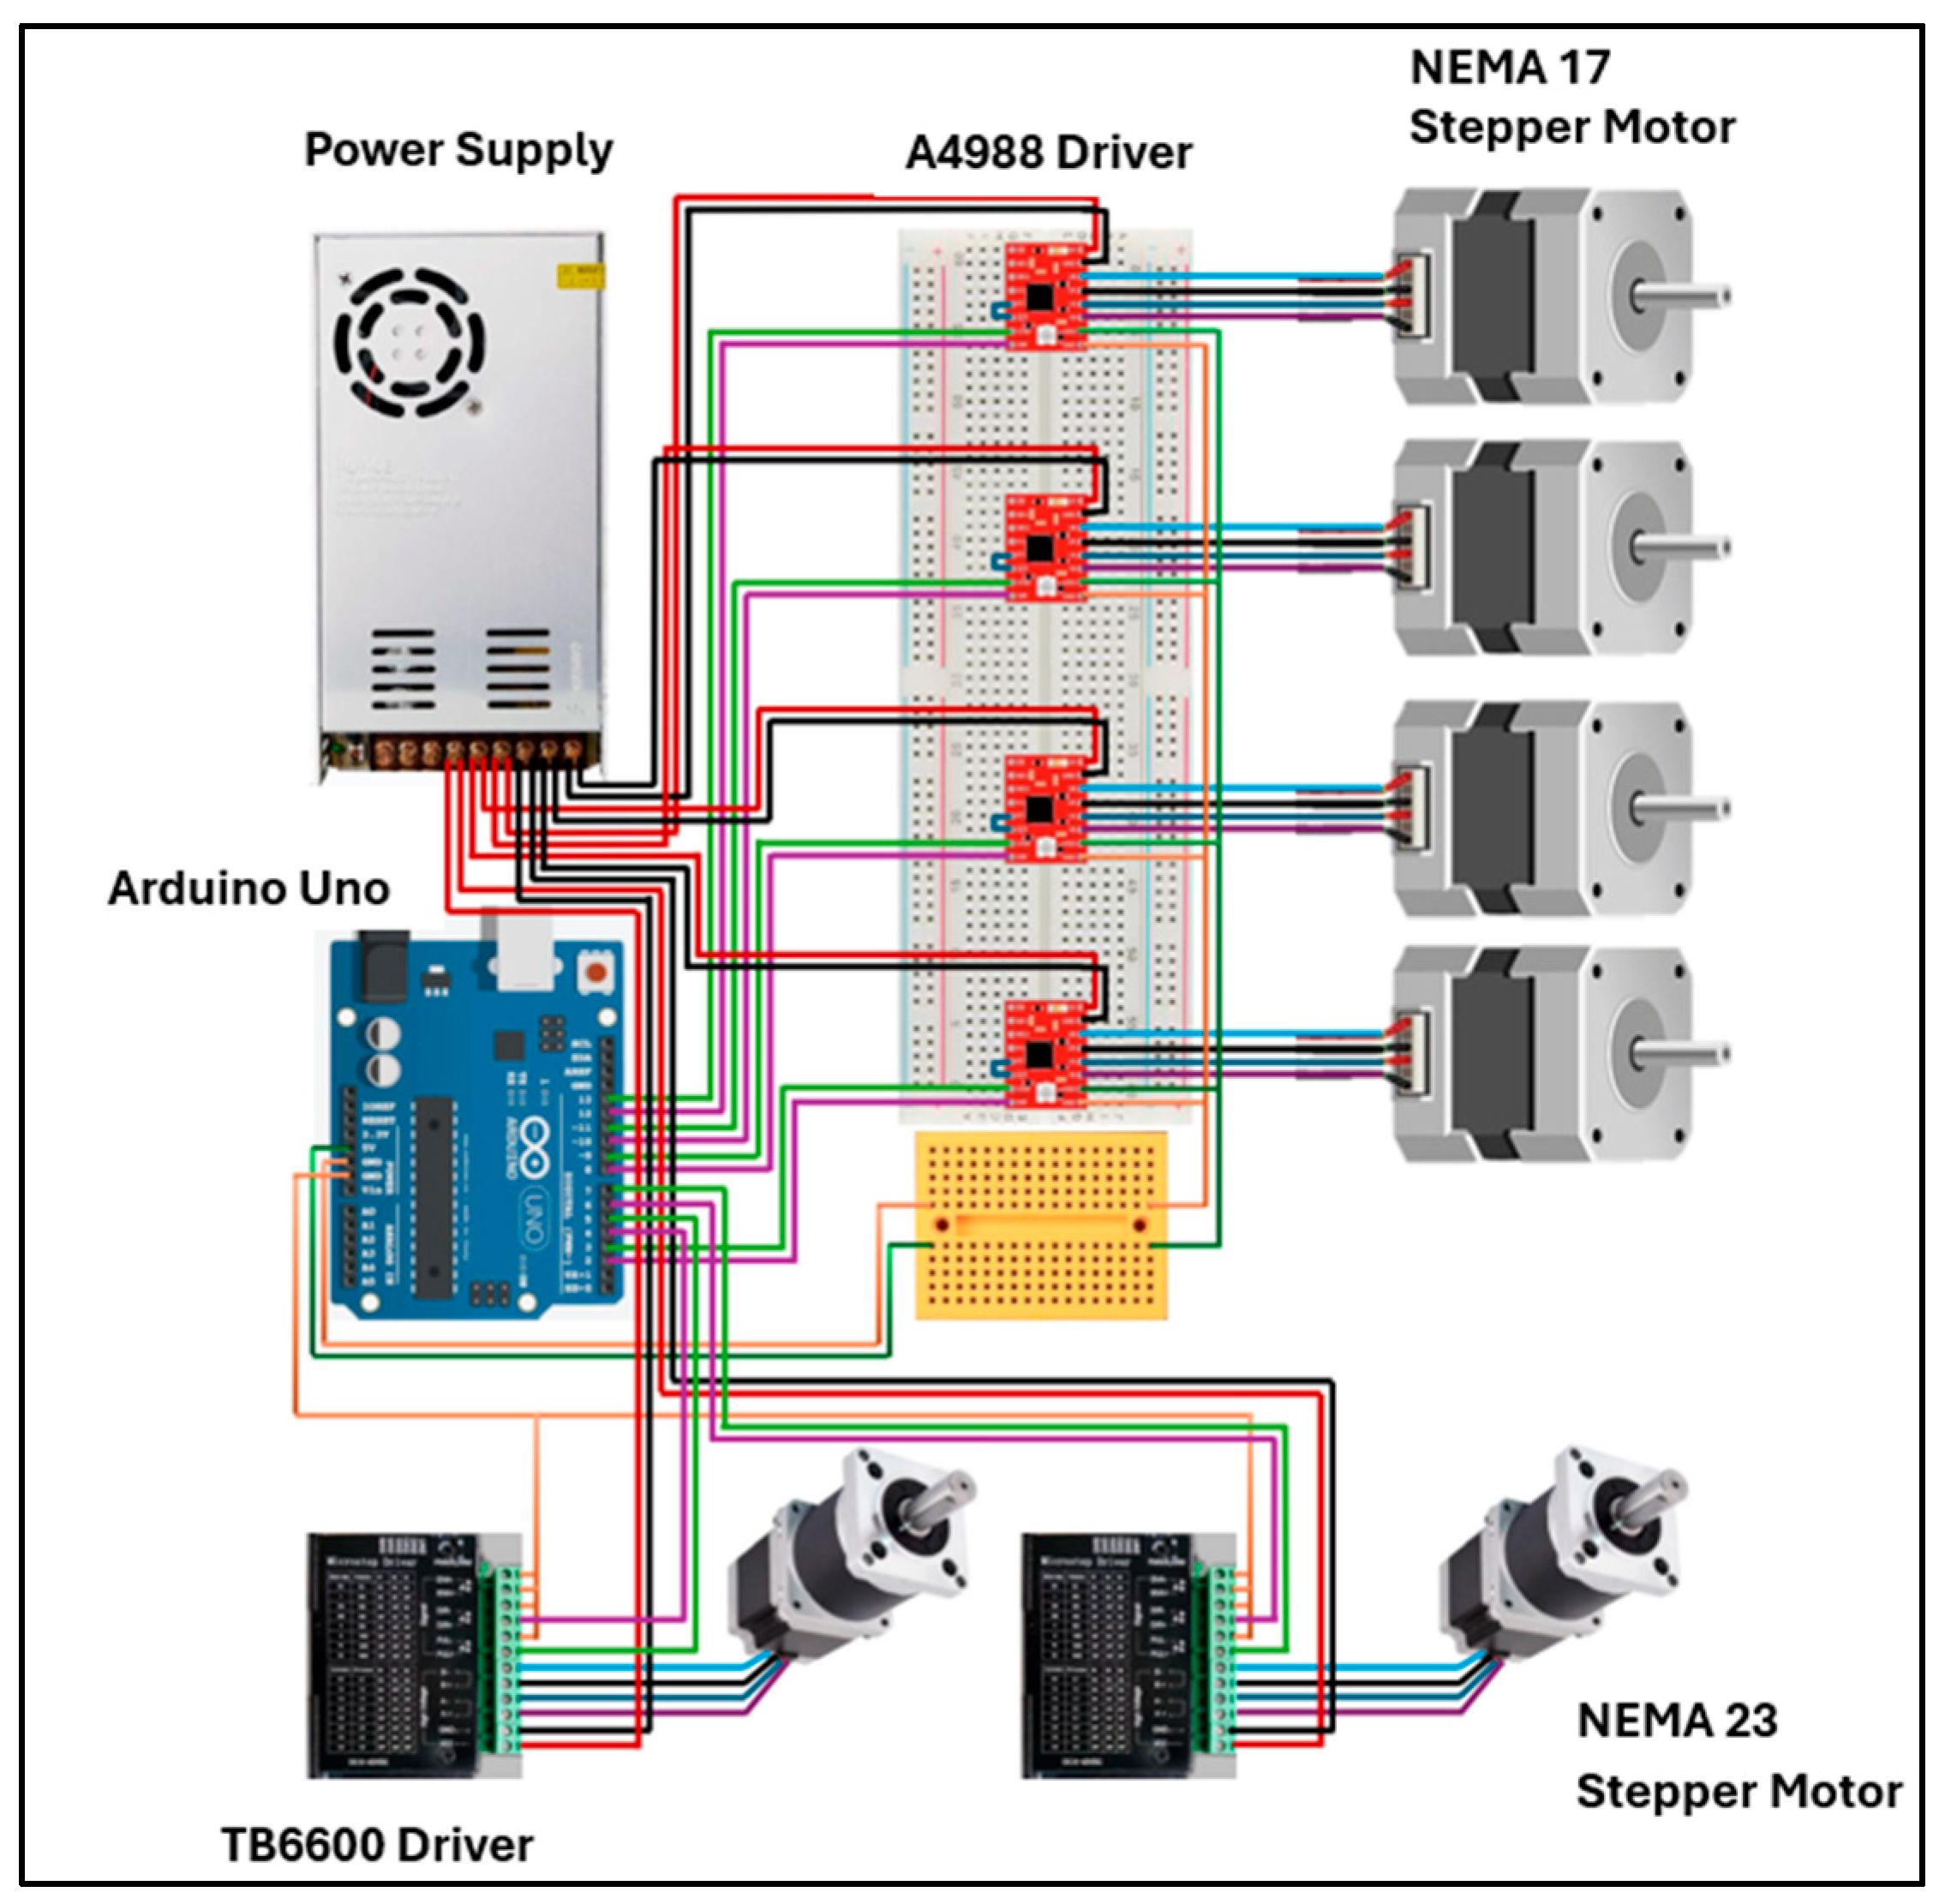
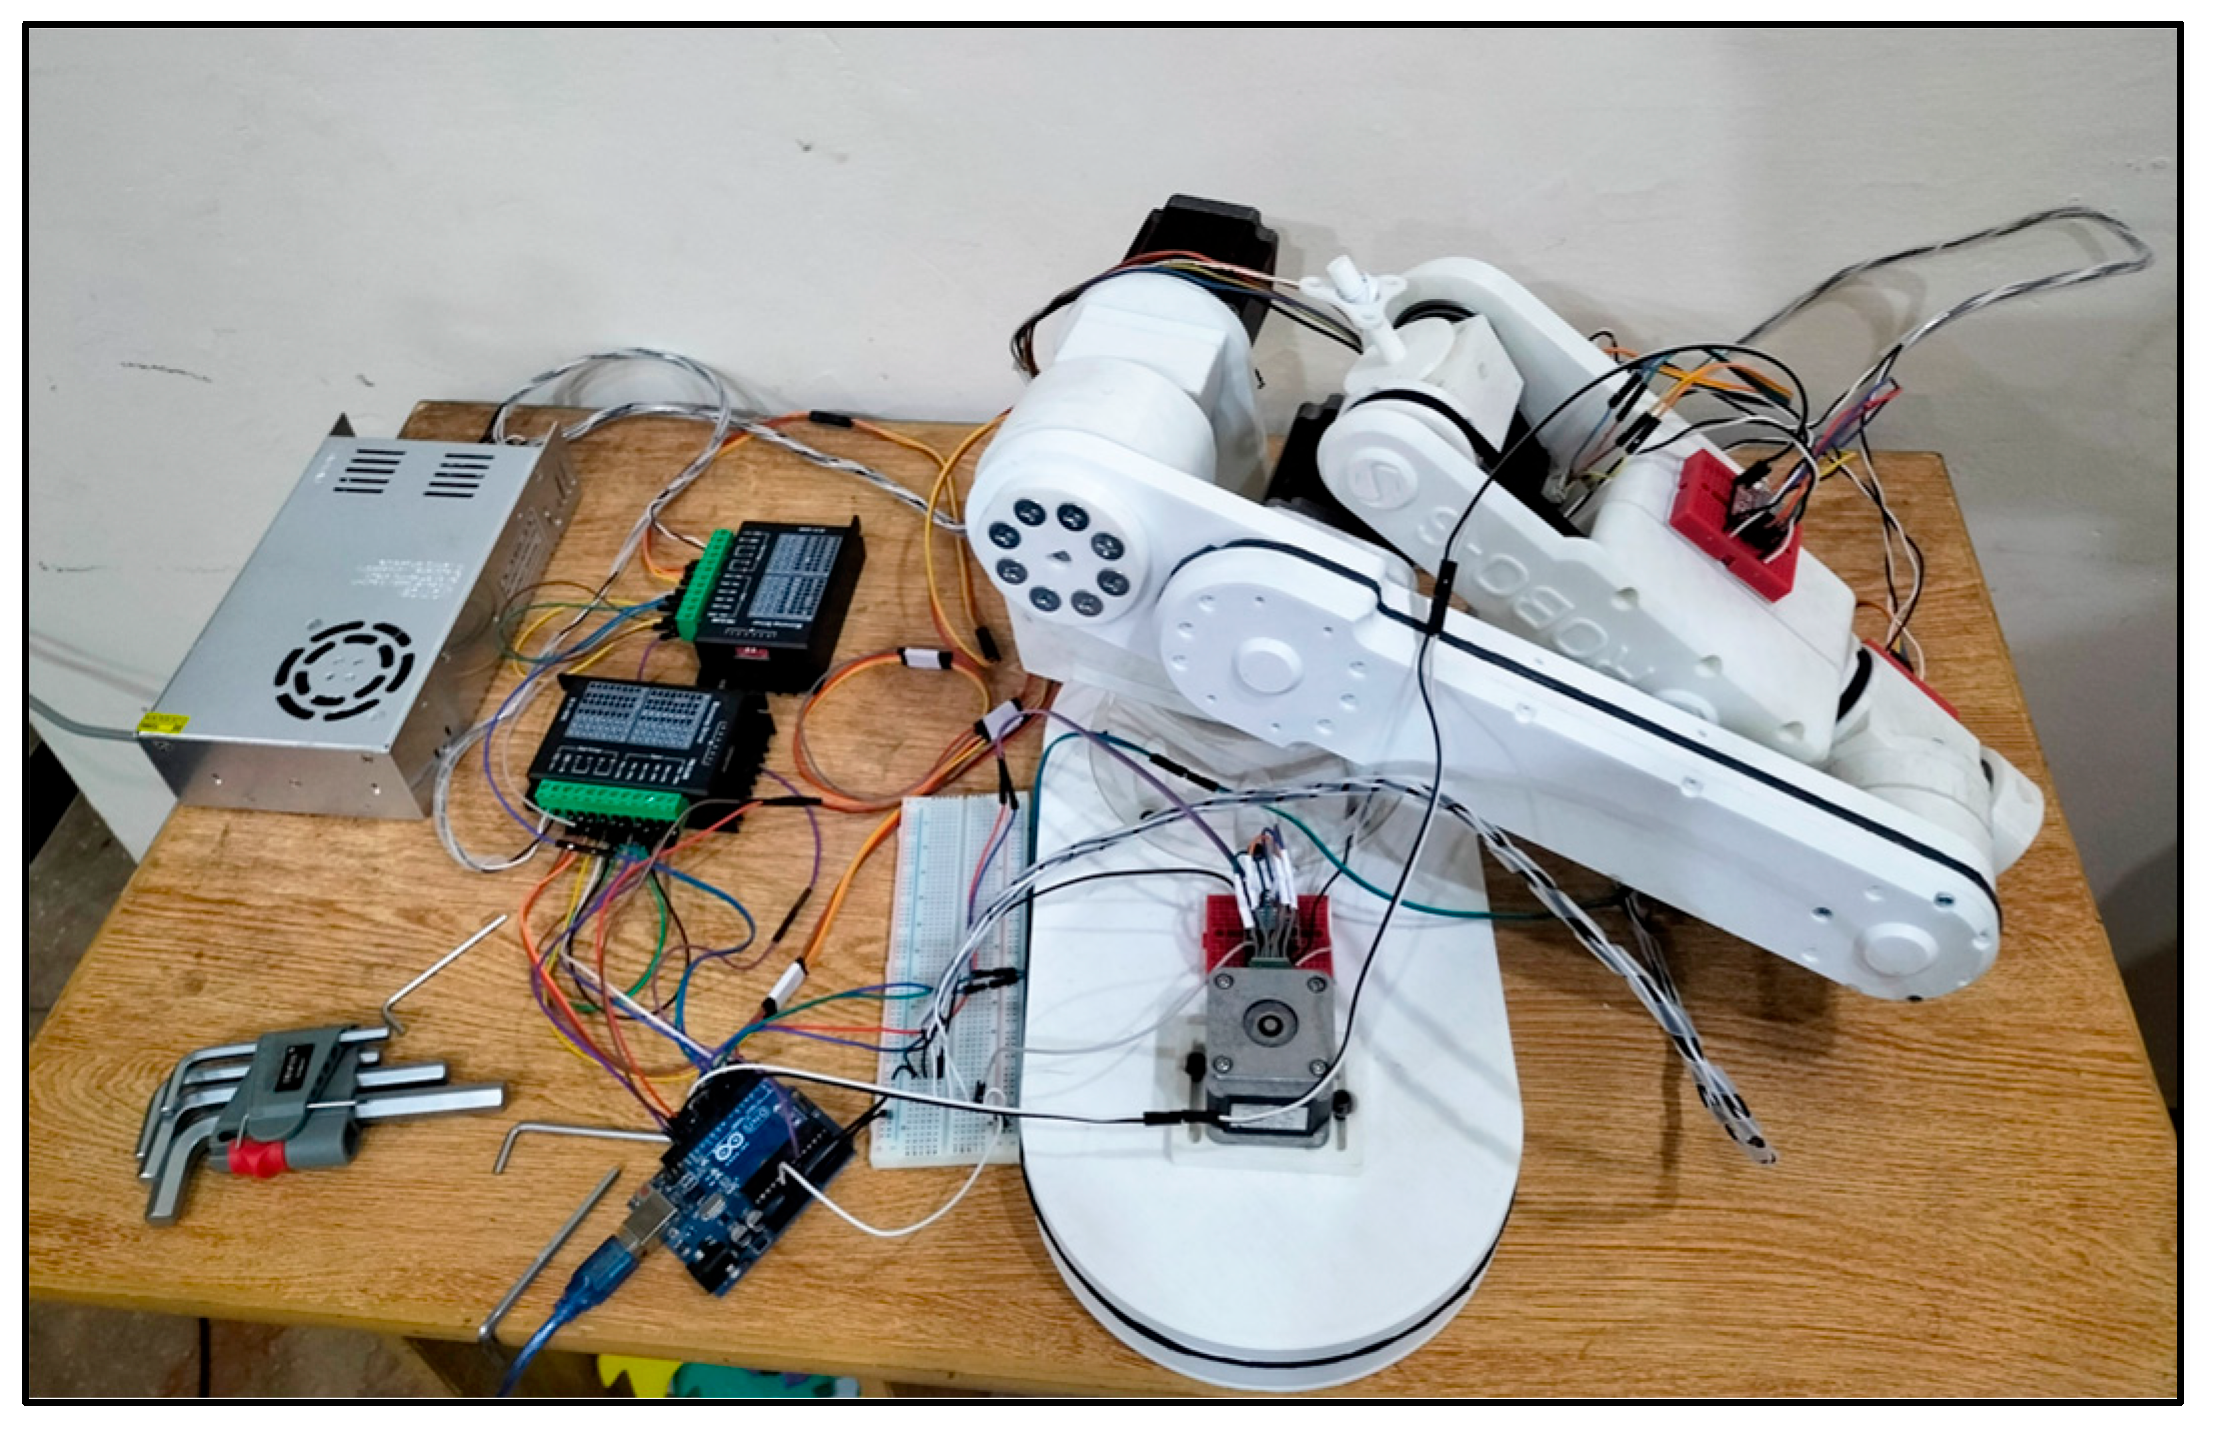
3.4. Prototype Development
4. Results
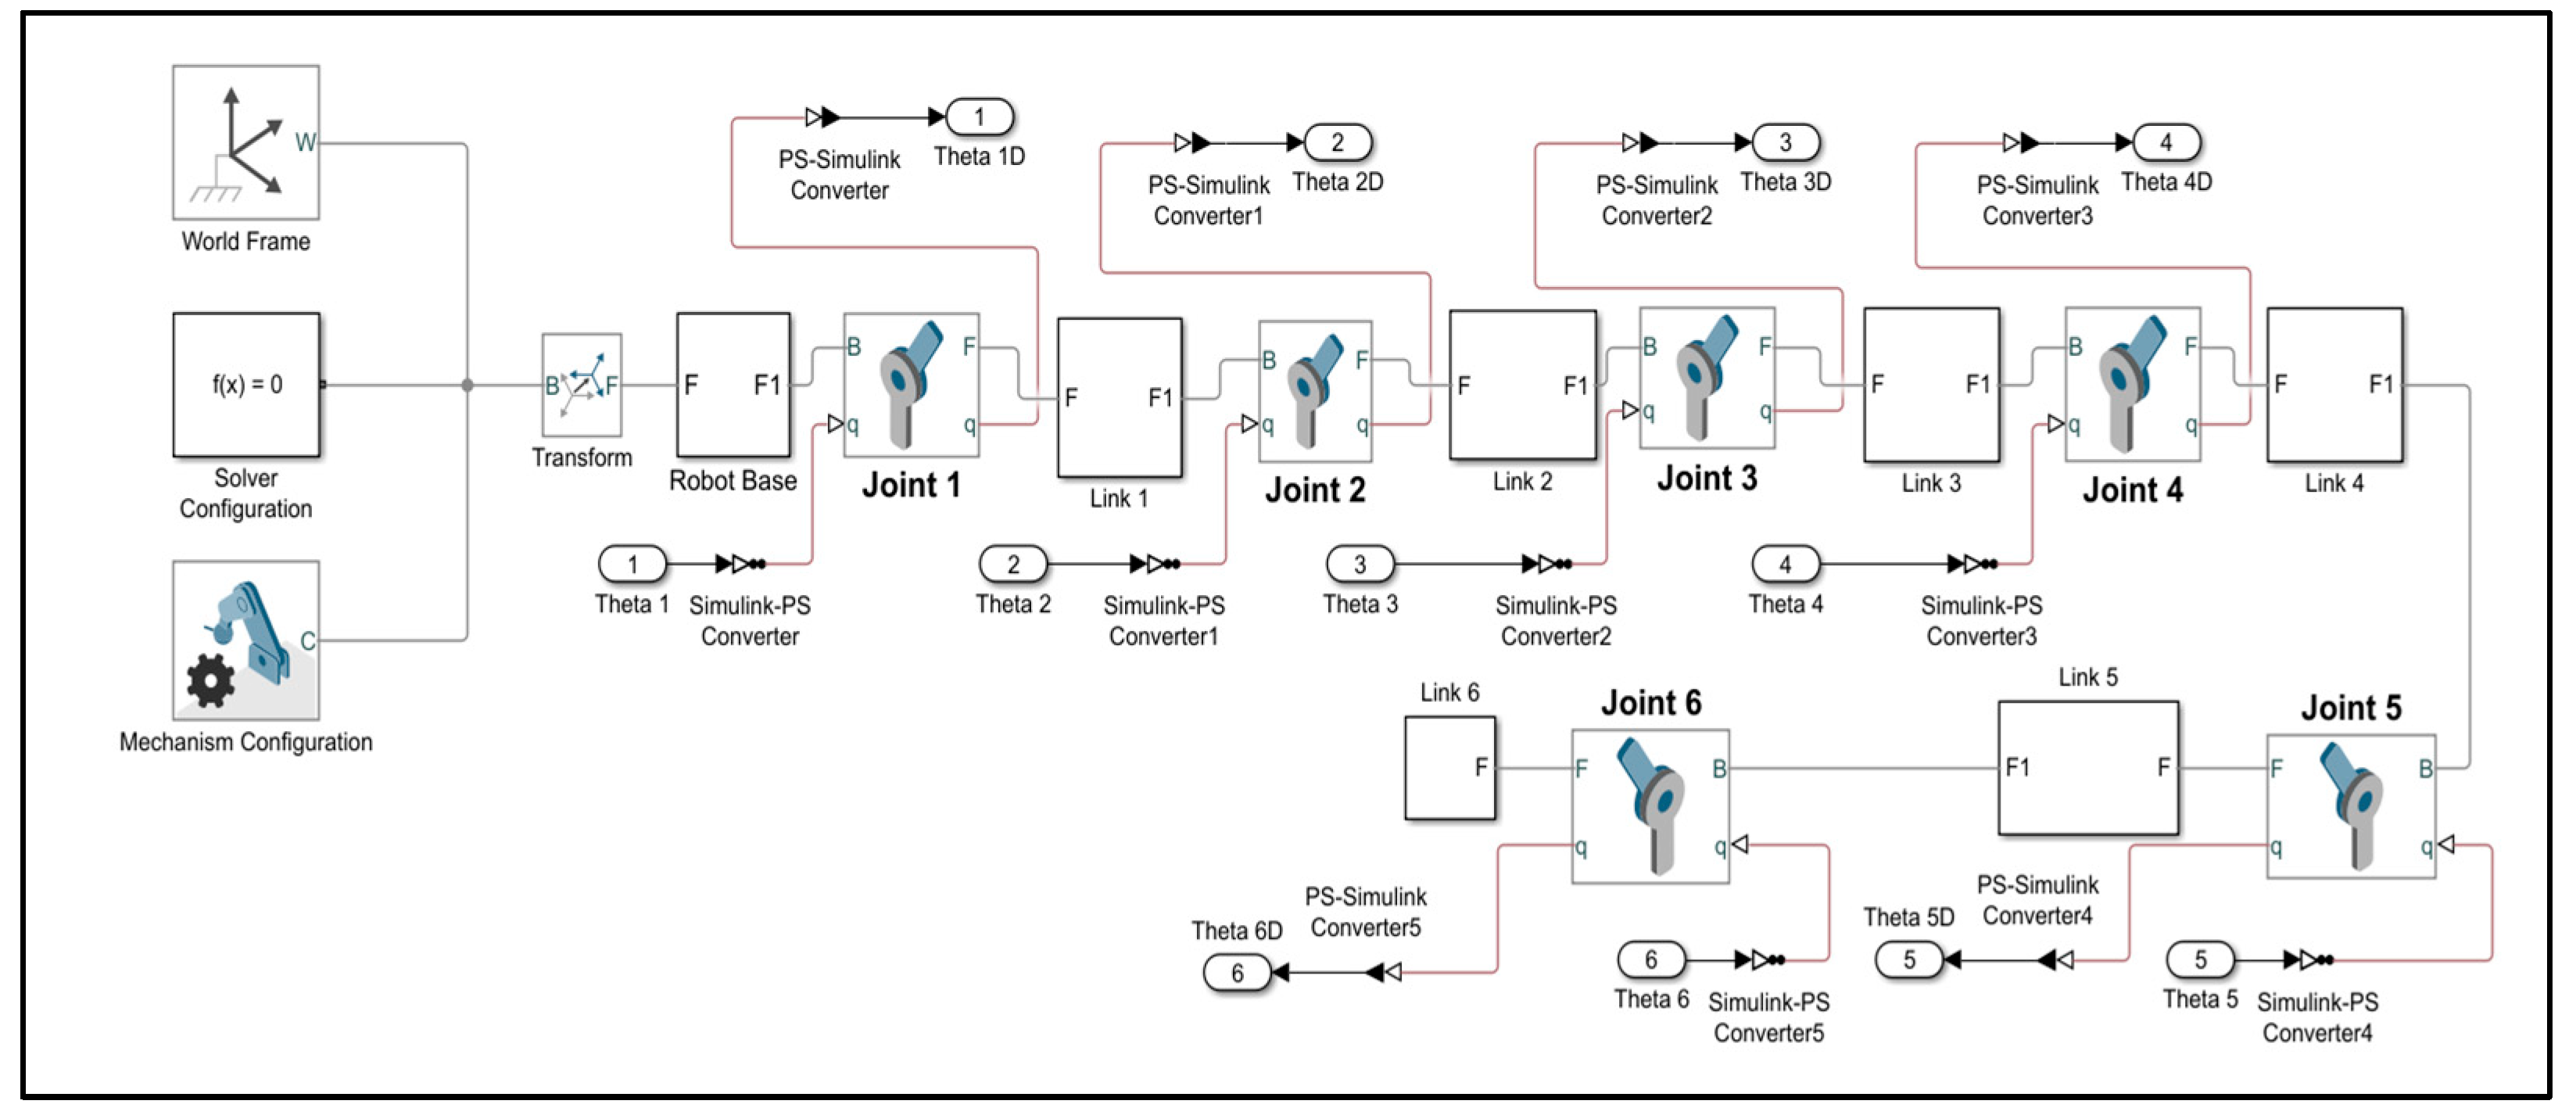
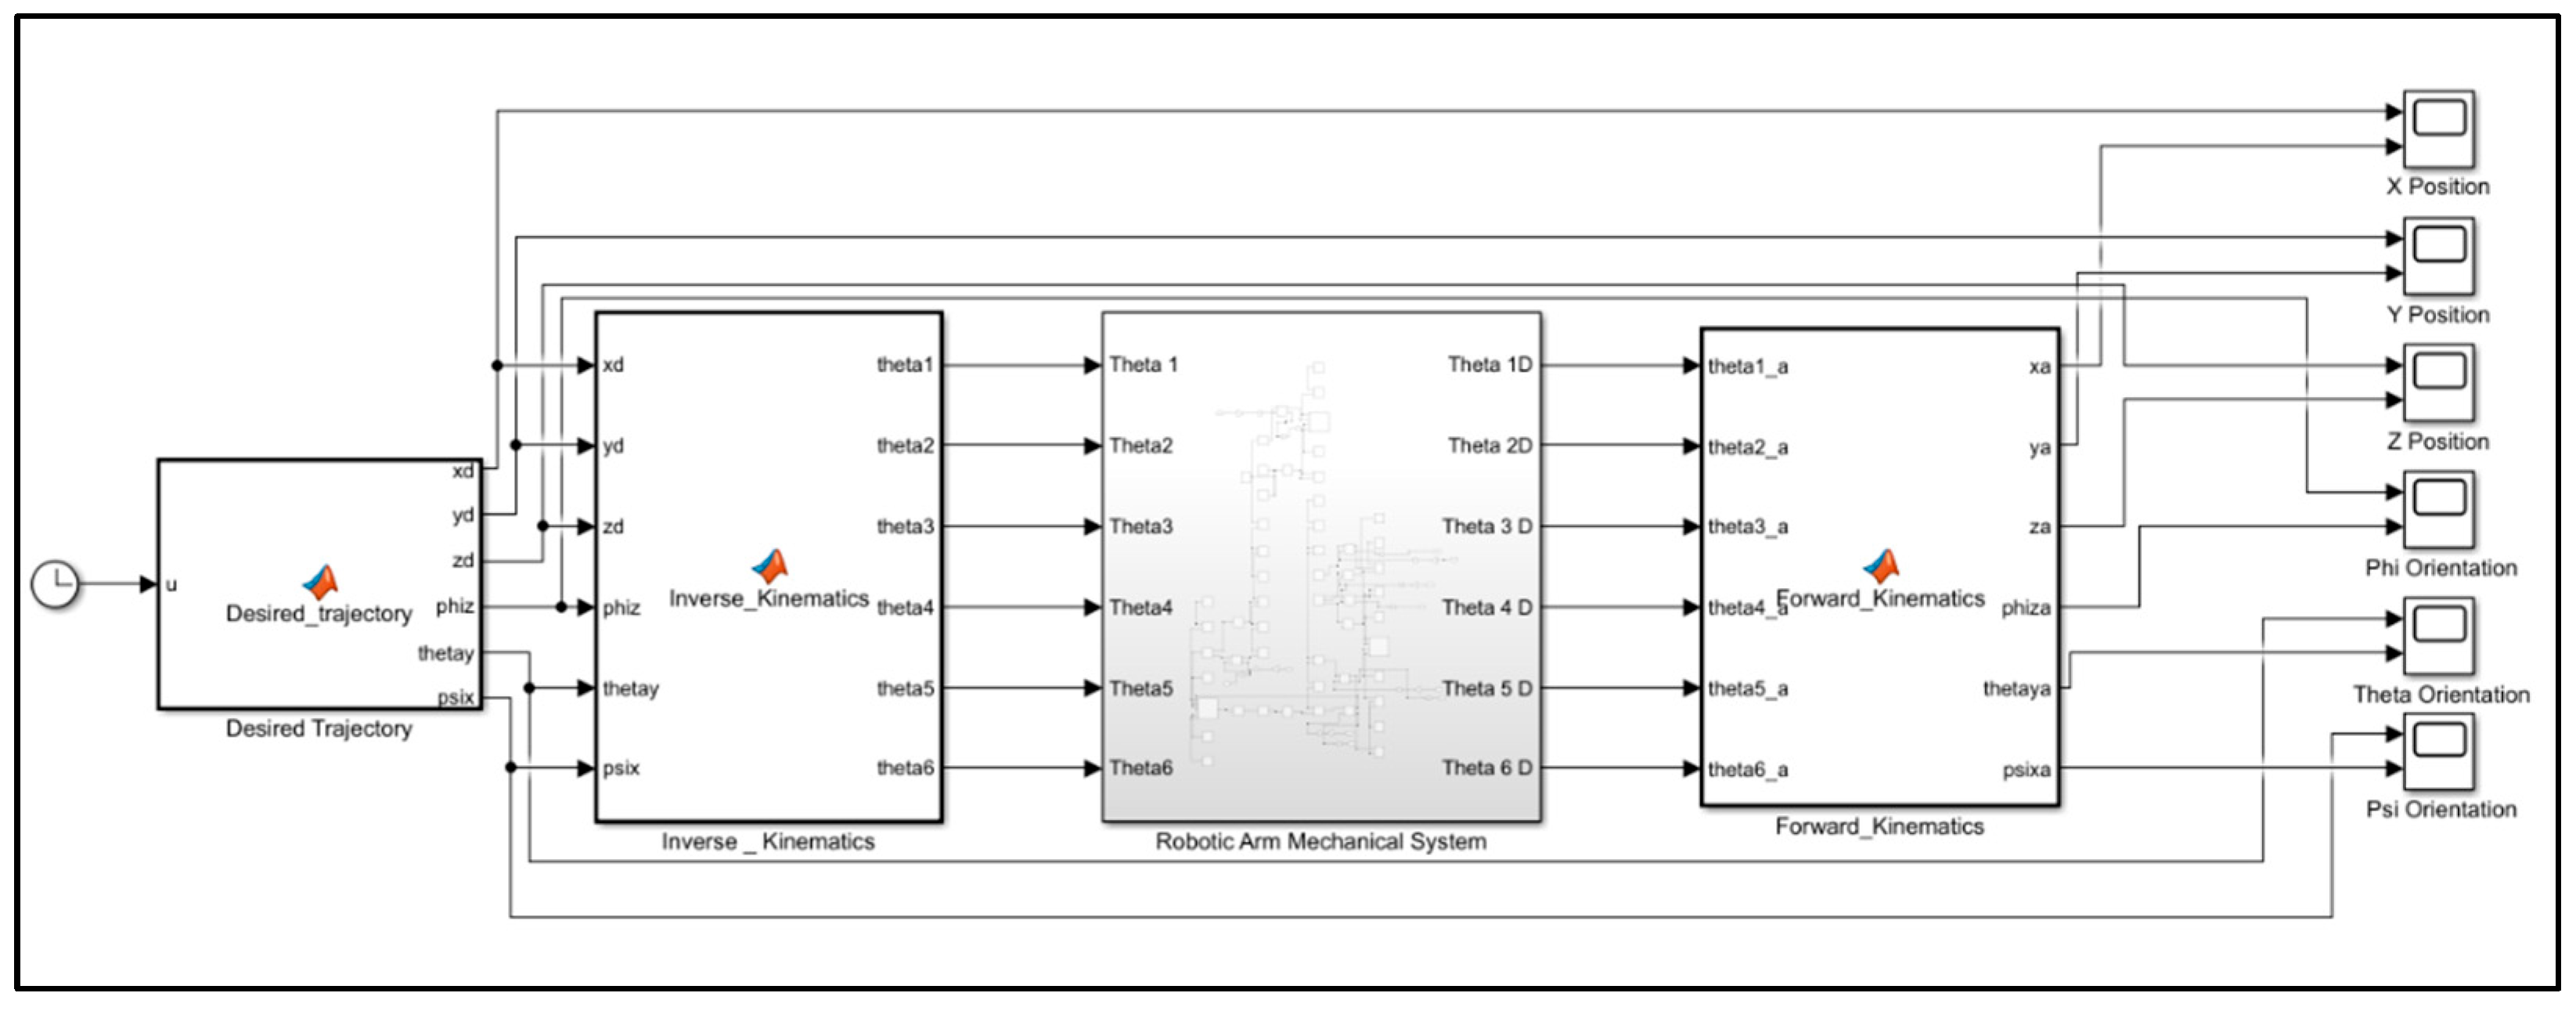
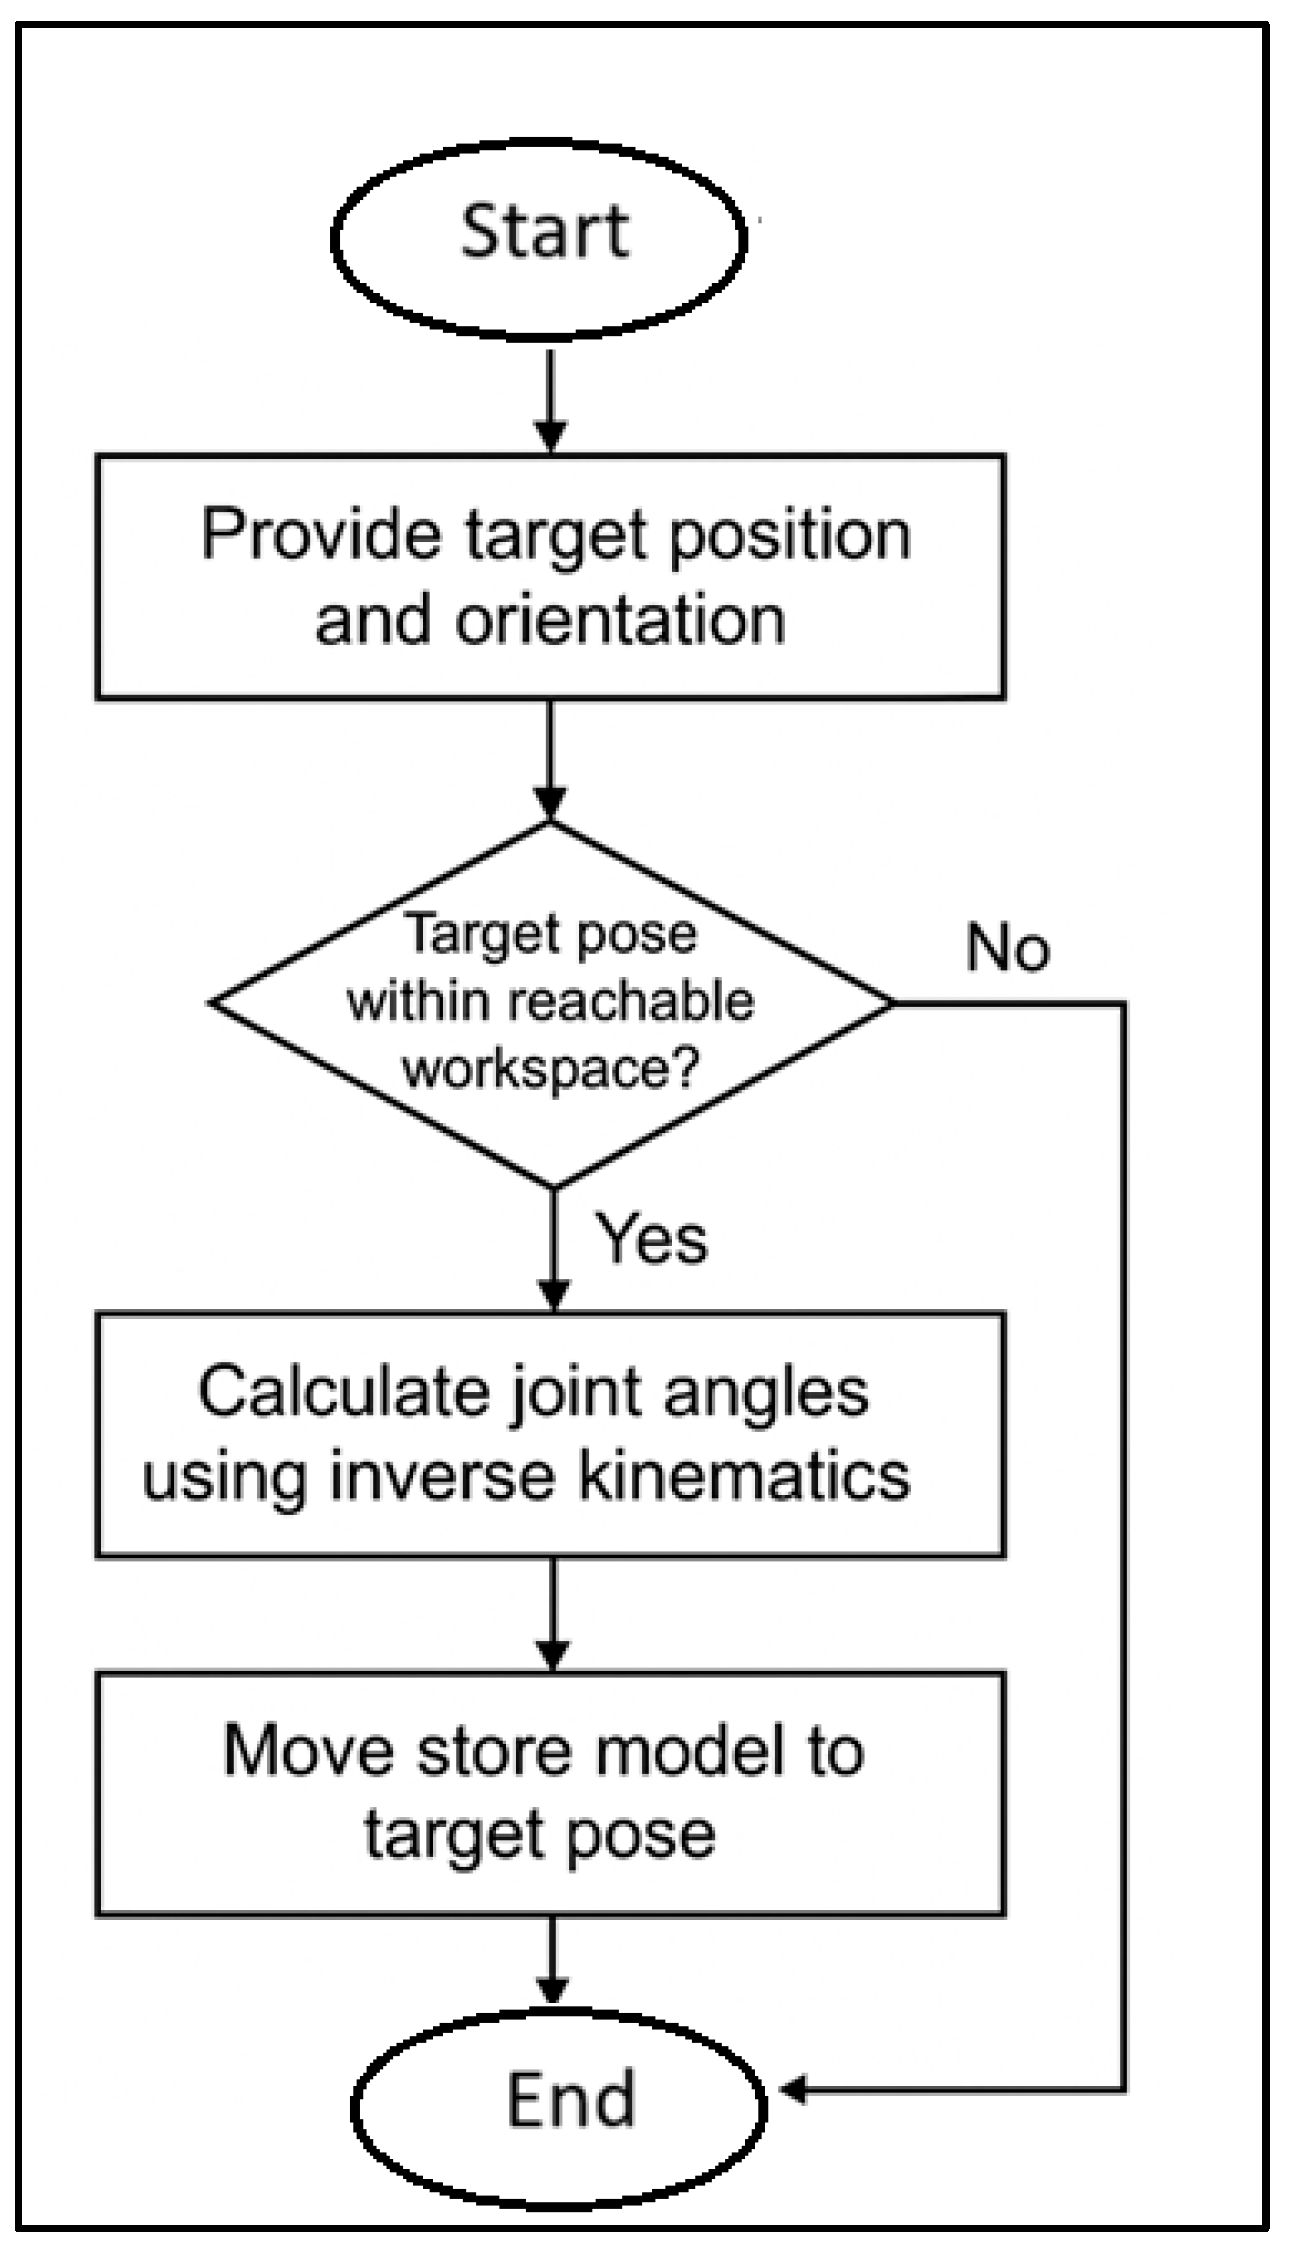
4.1. Simulation Workflow
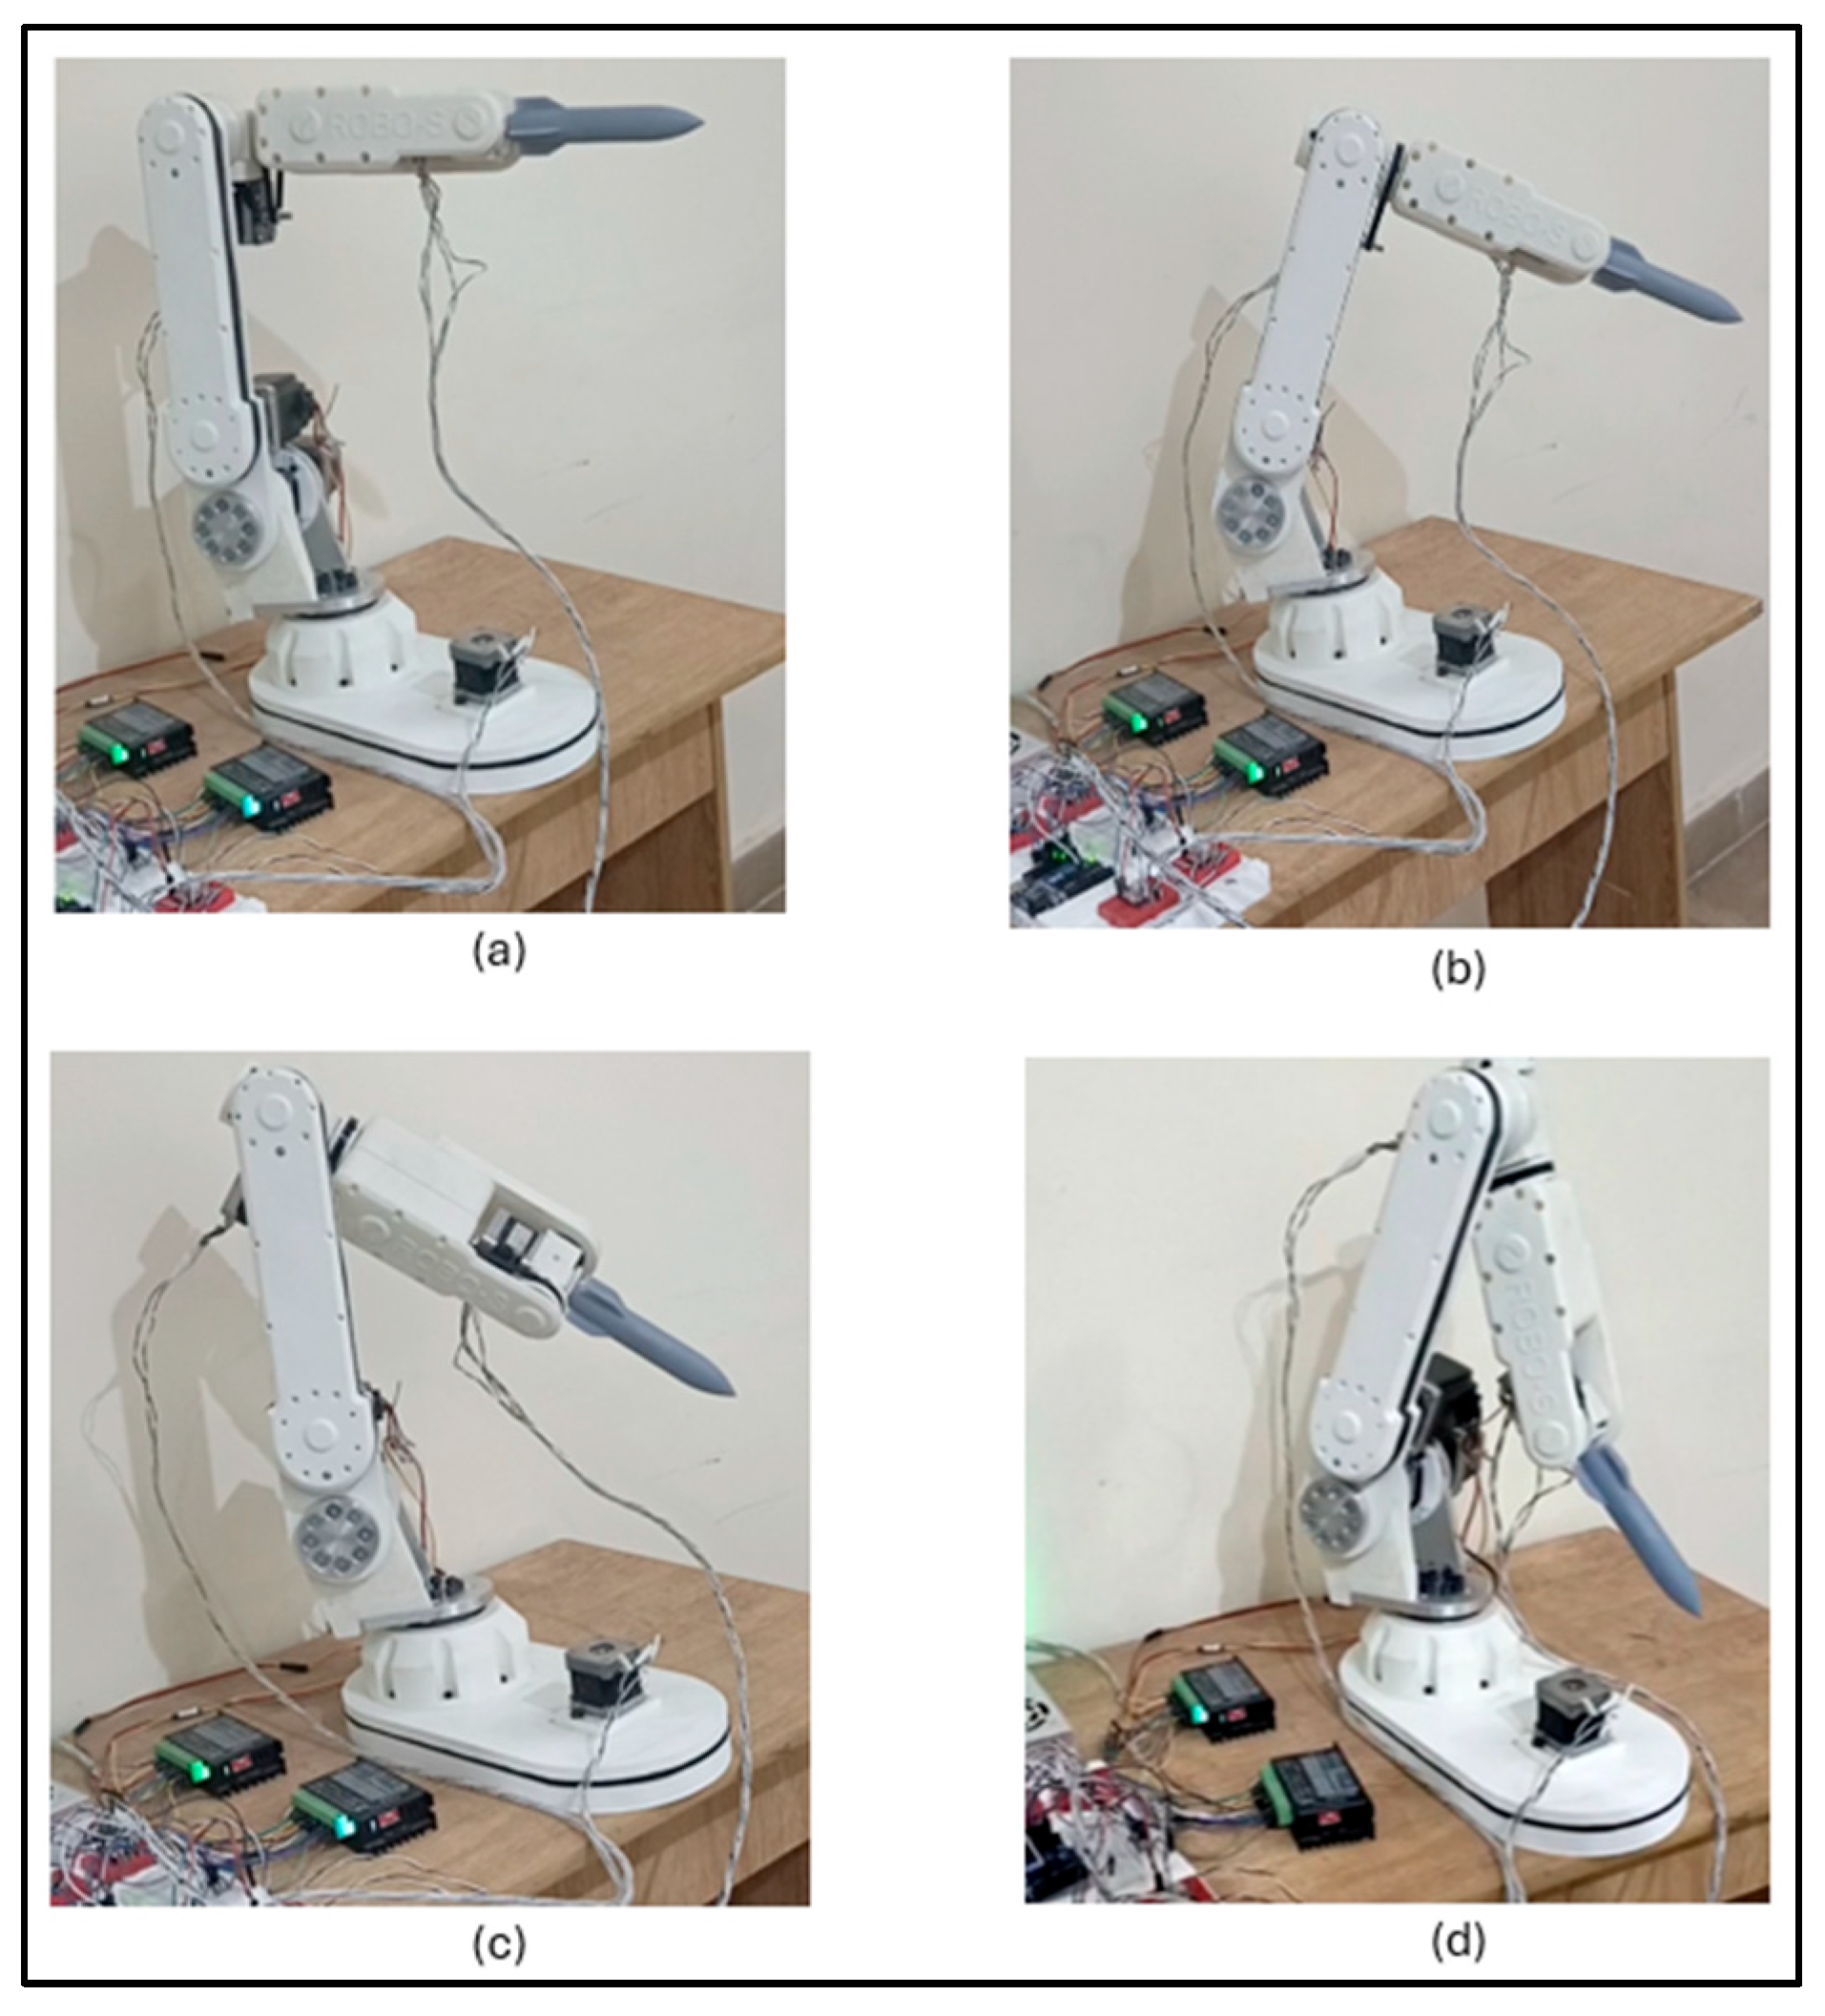
4.2. Implementation of Inverse Kinematics Model on Prototype
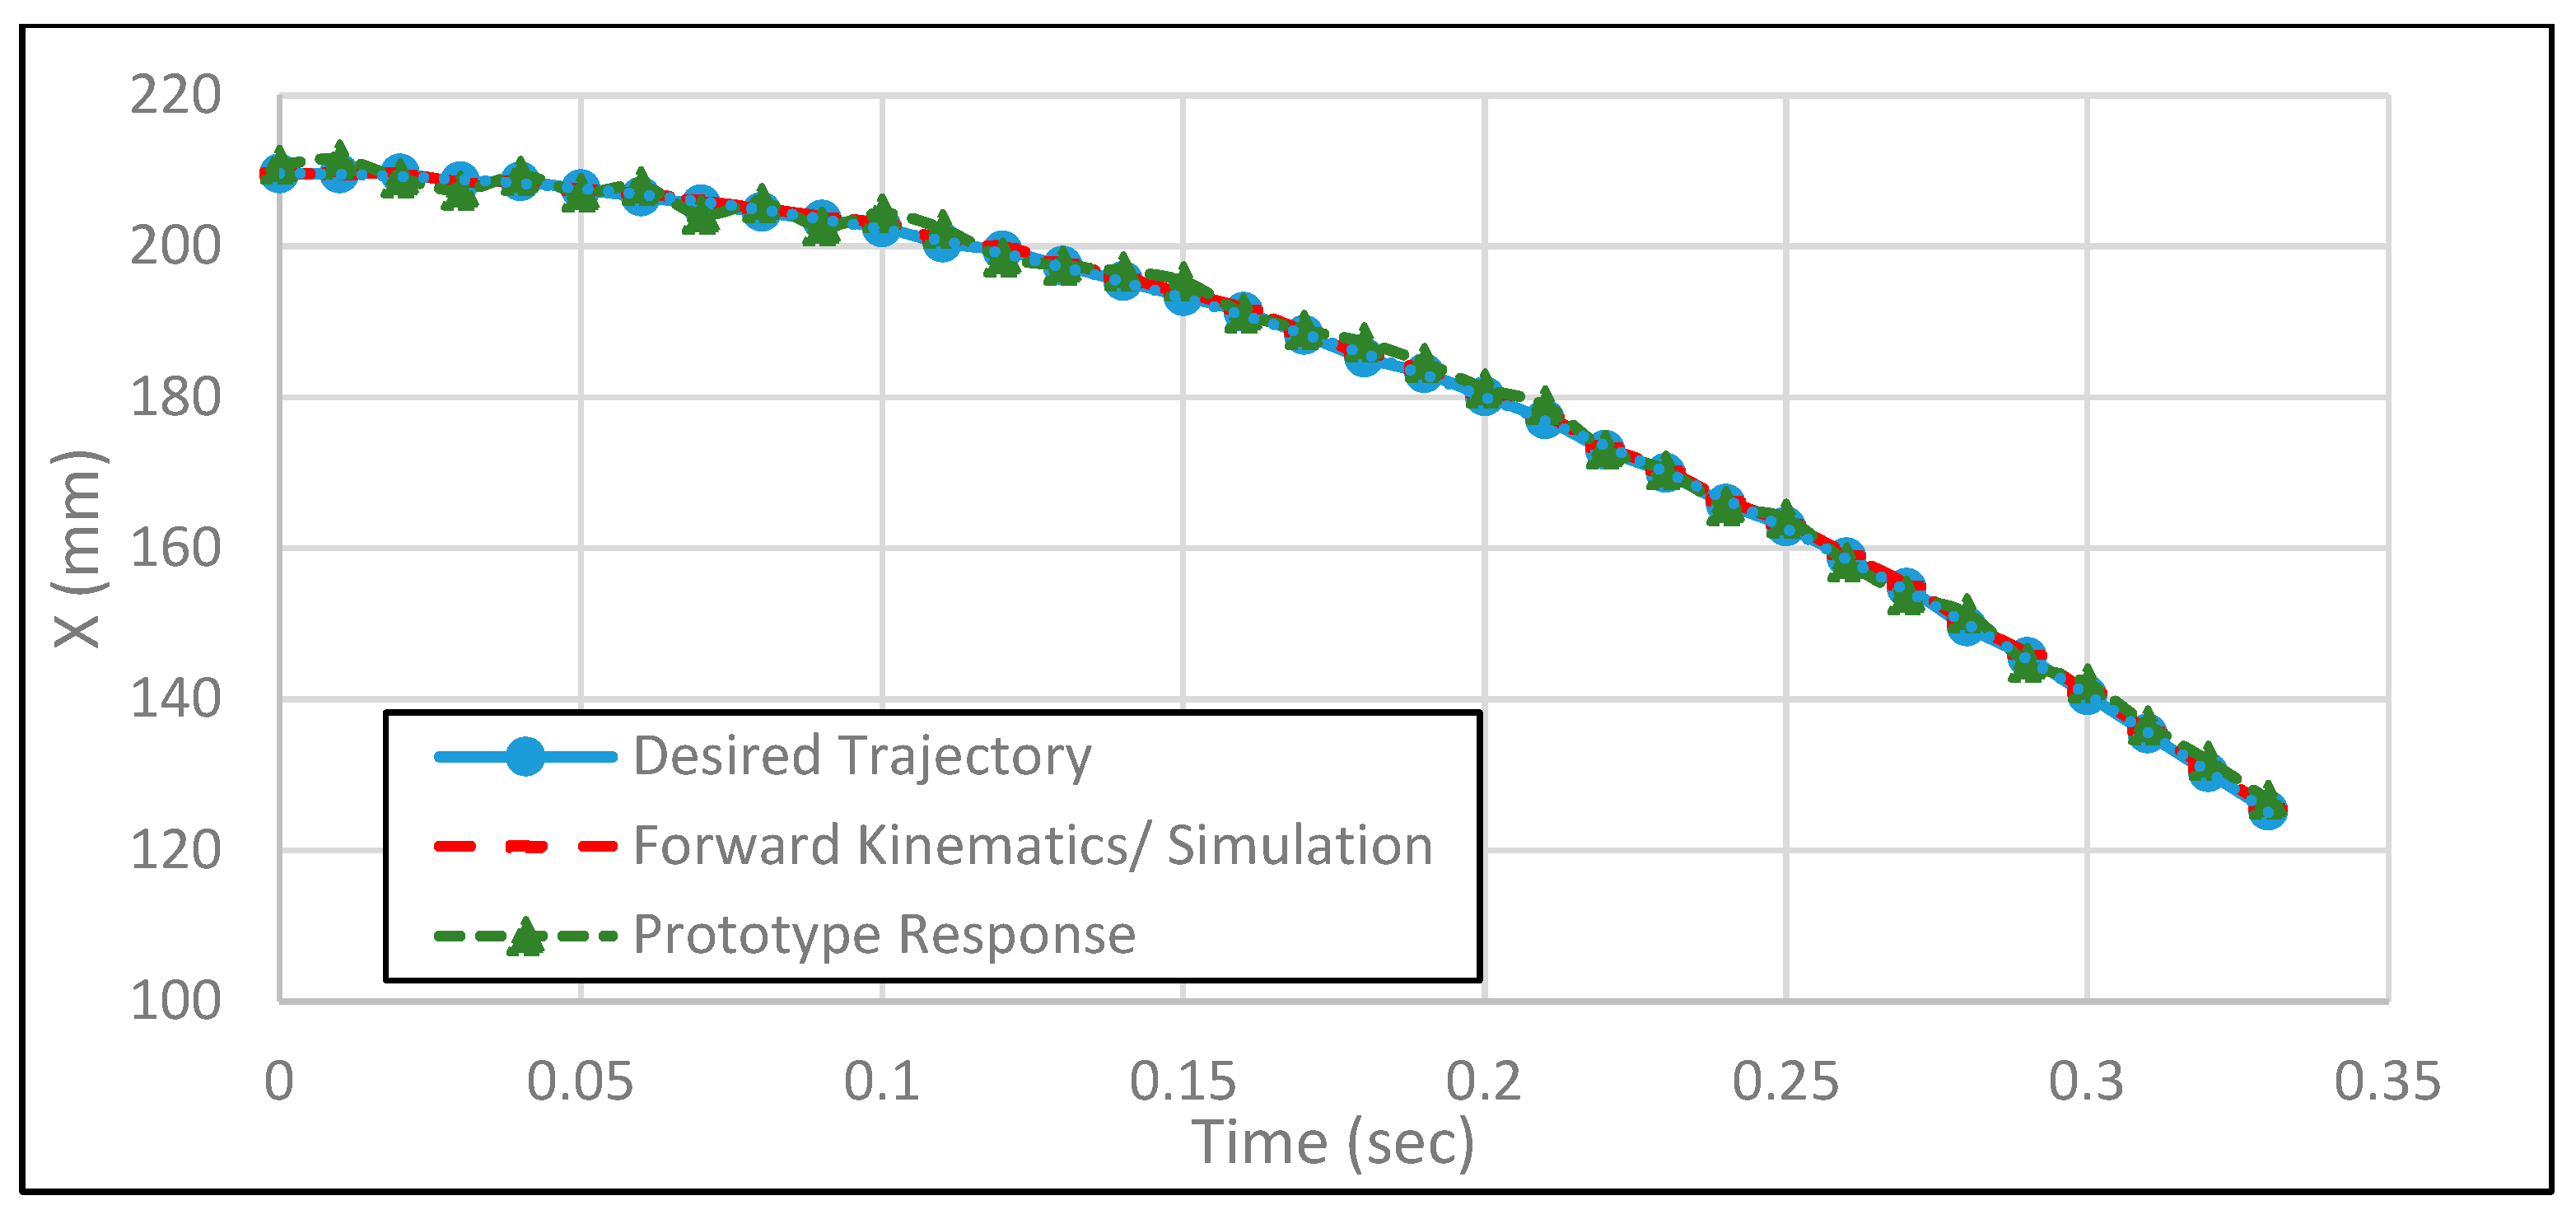
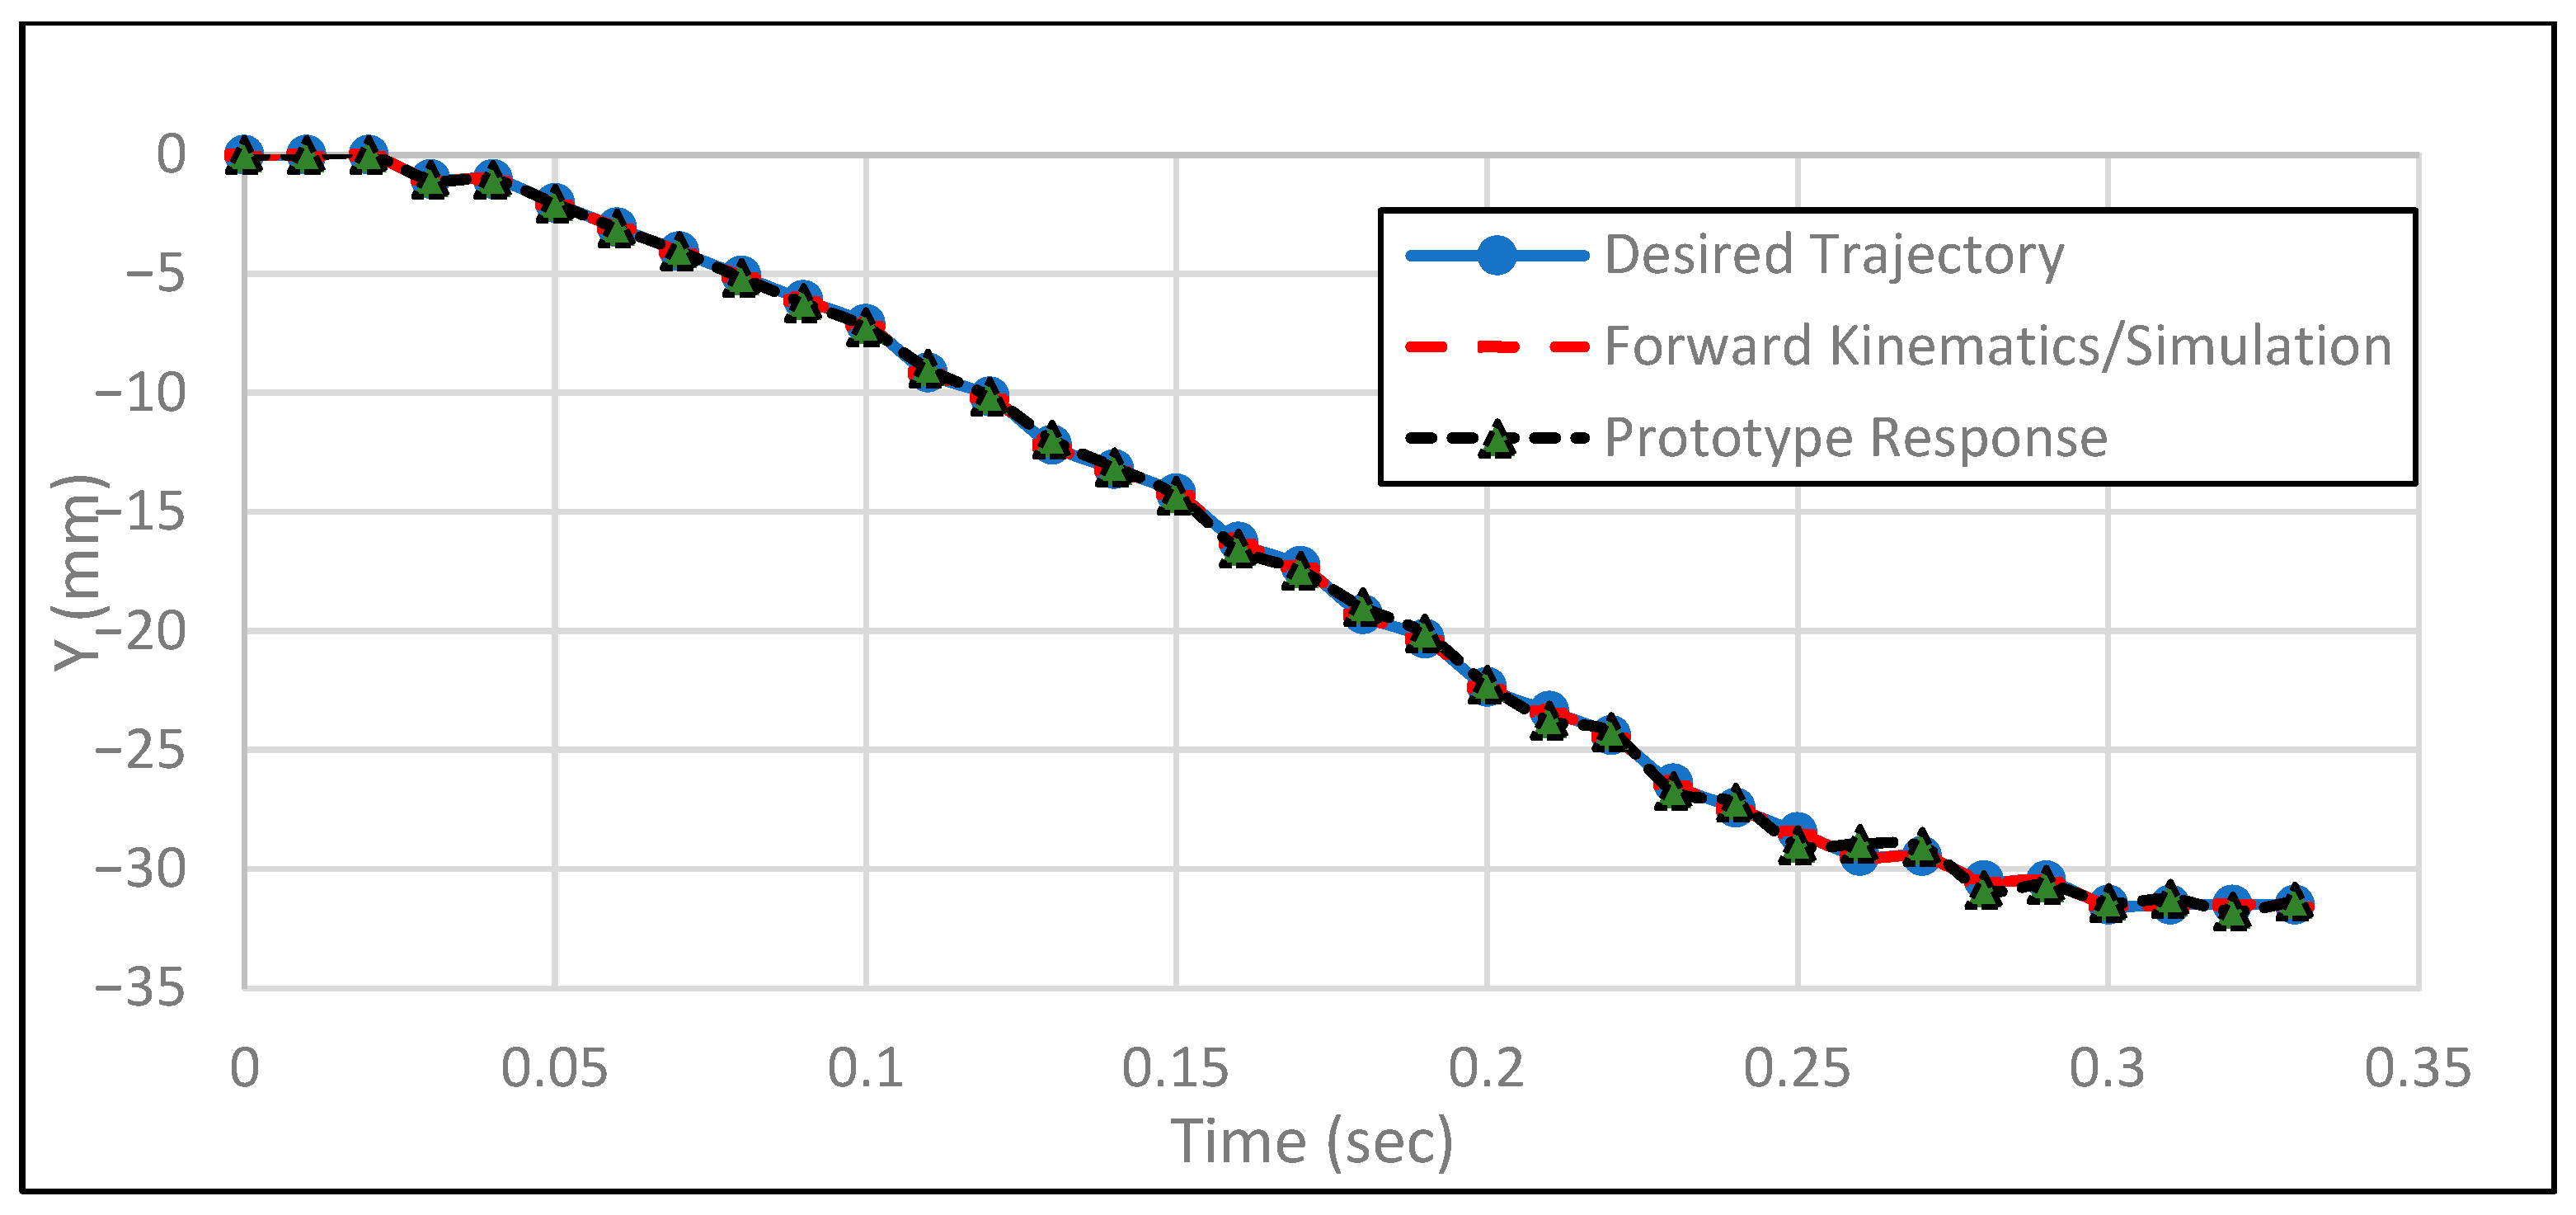
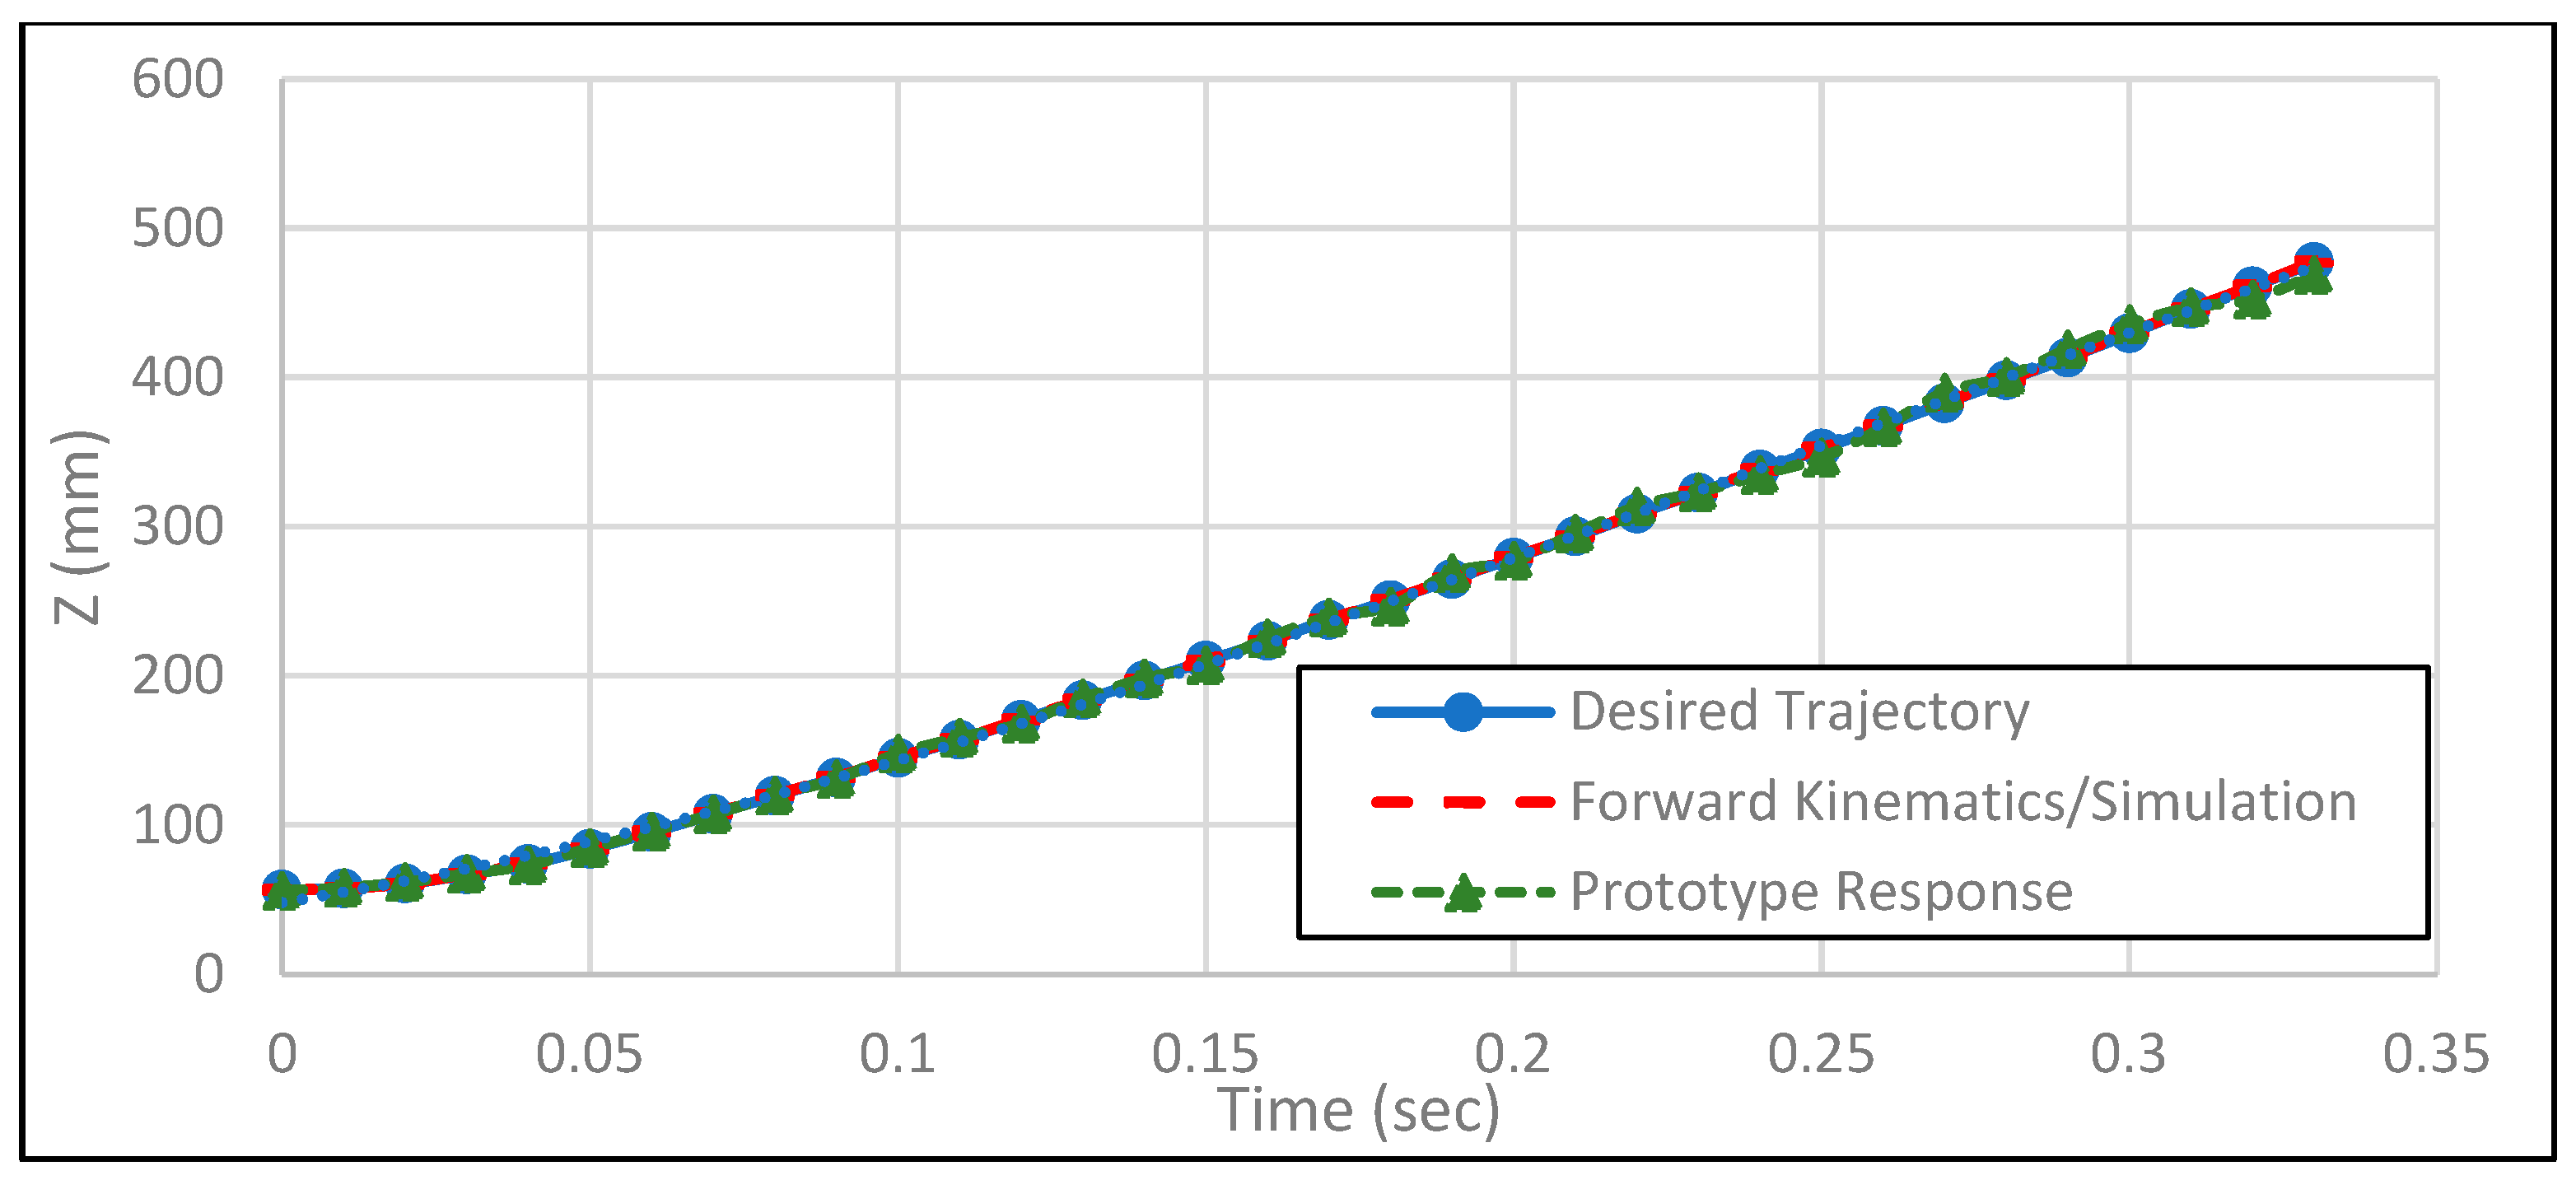
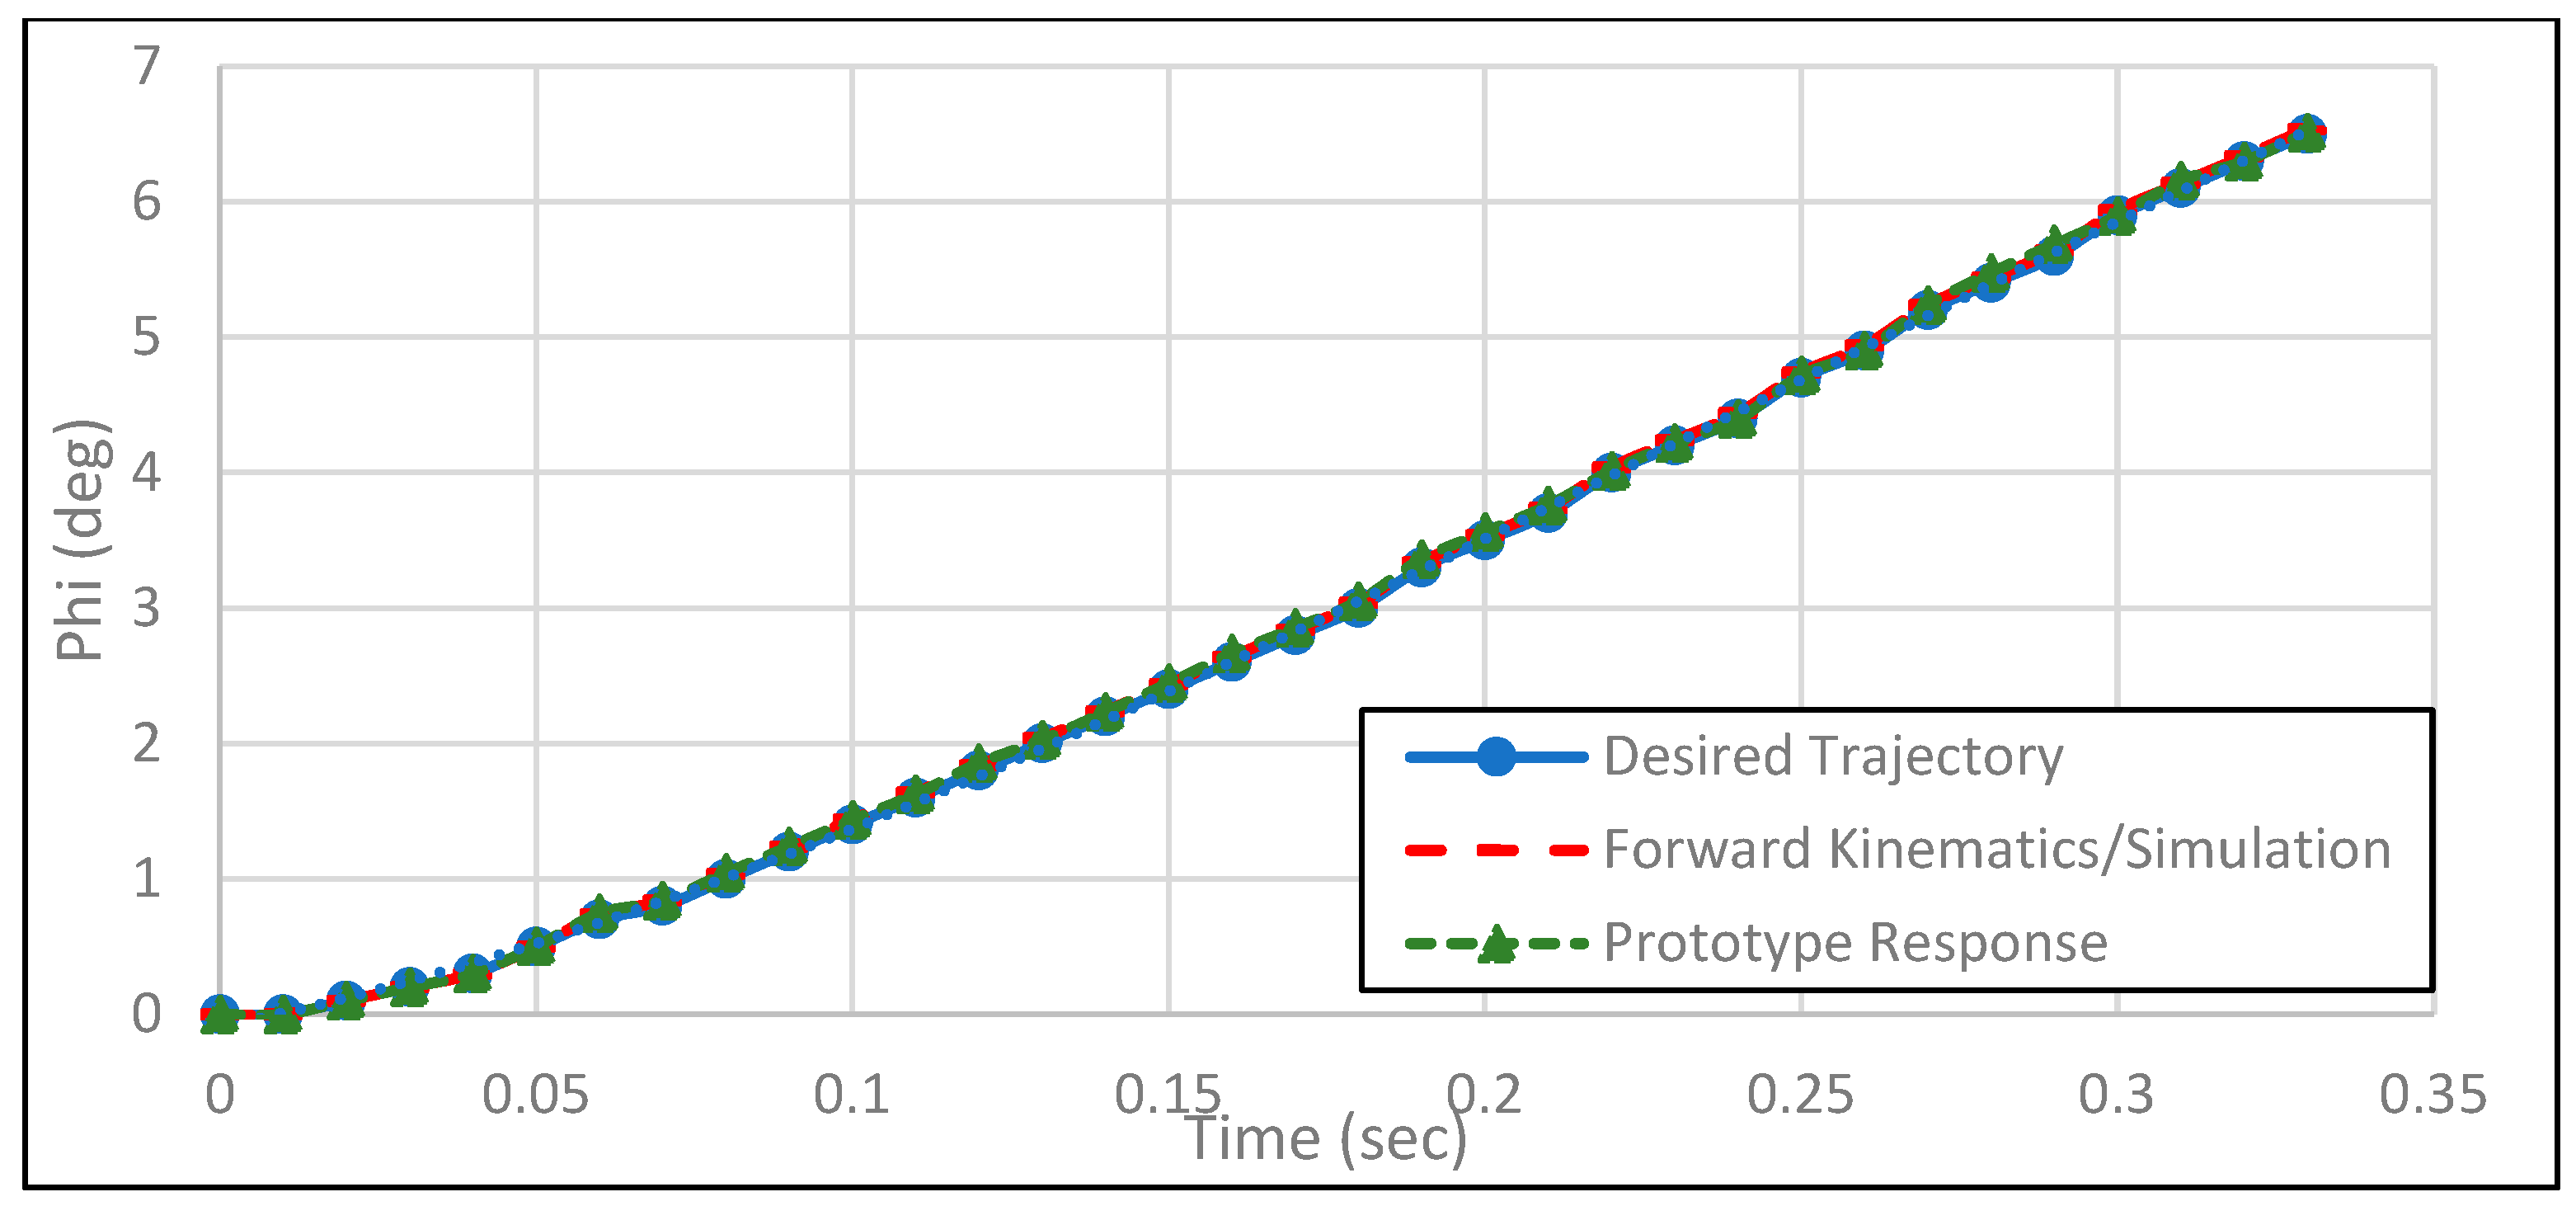
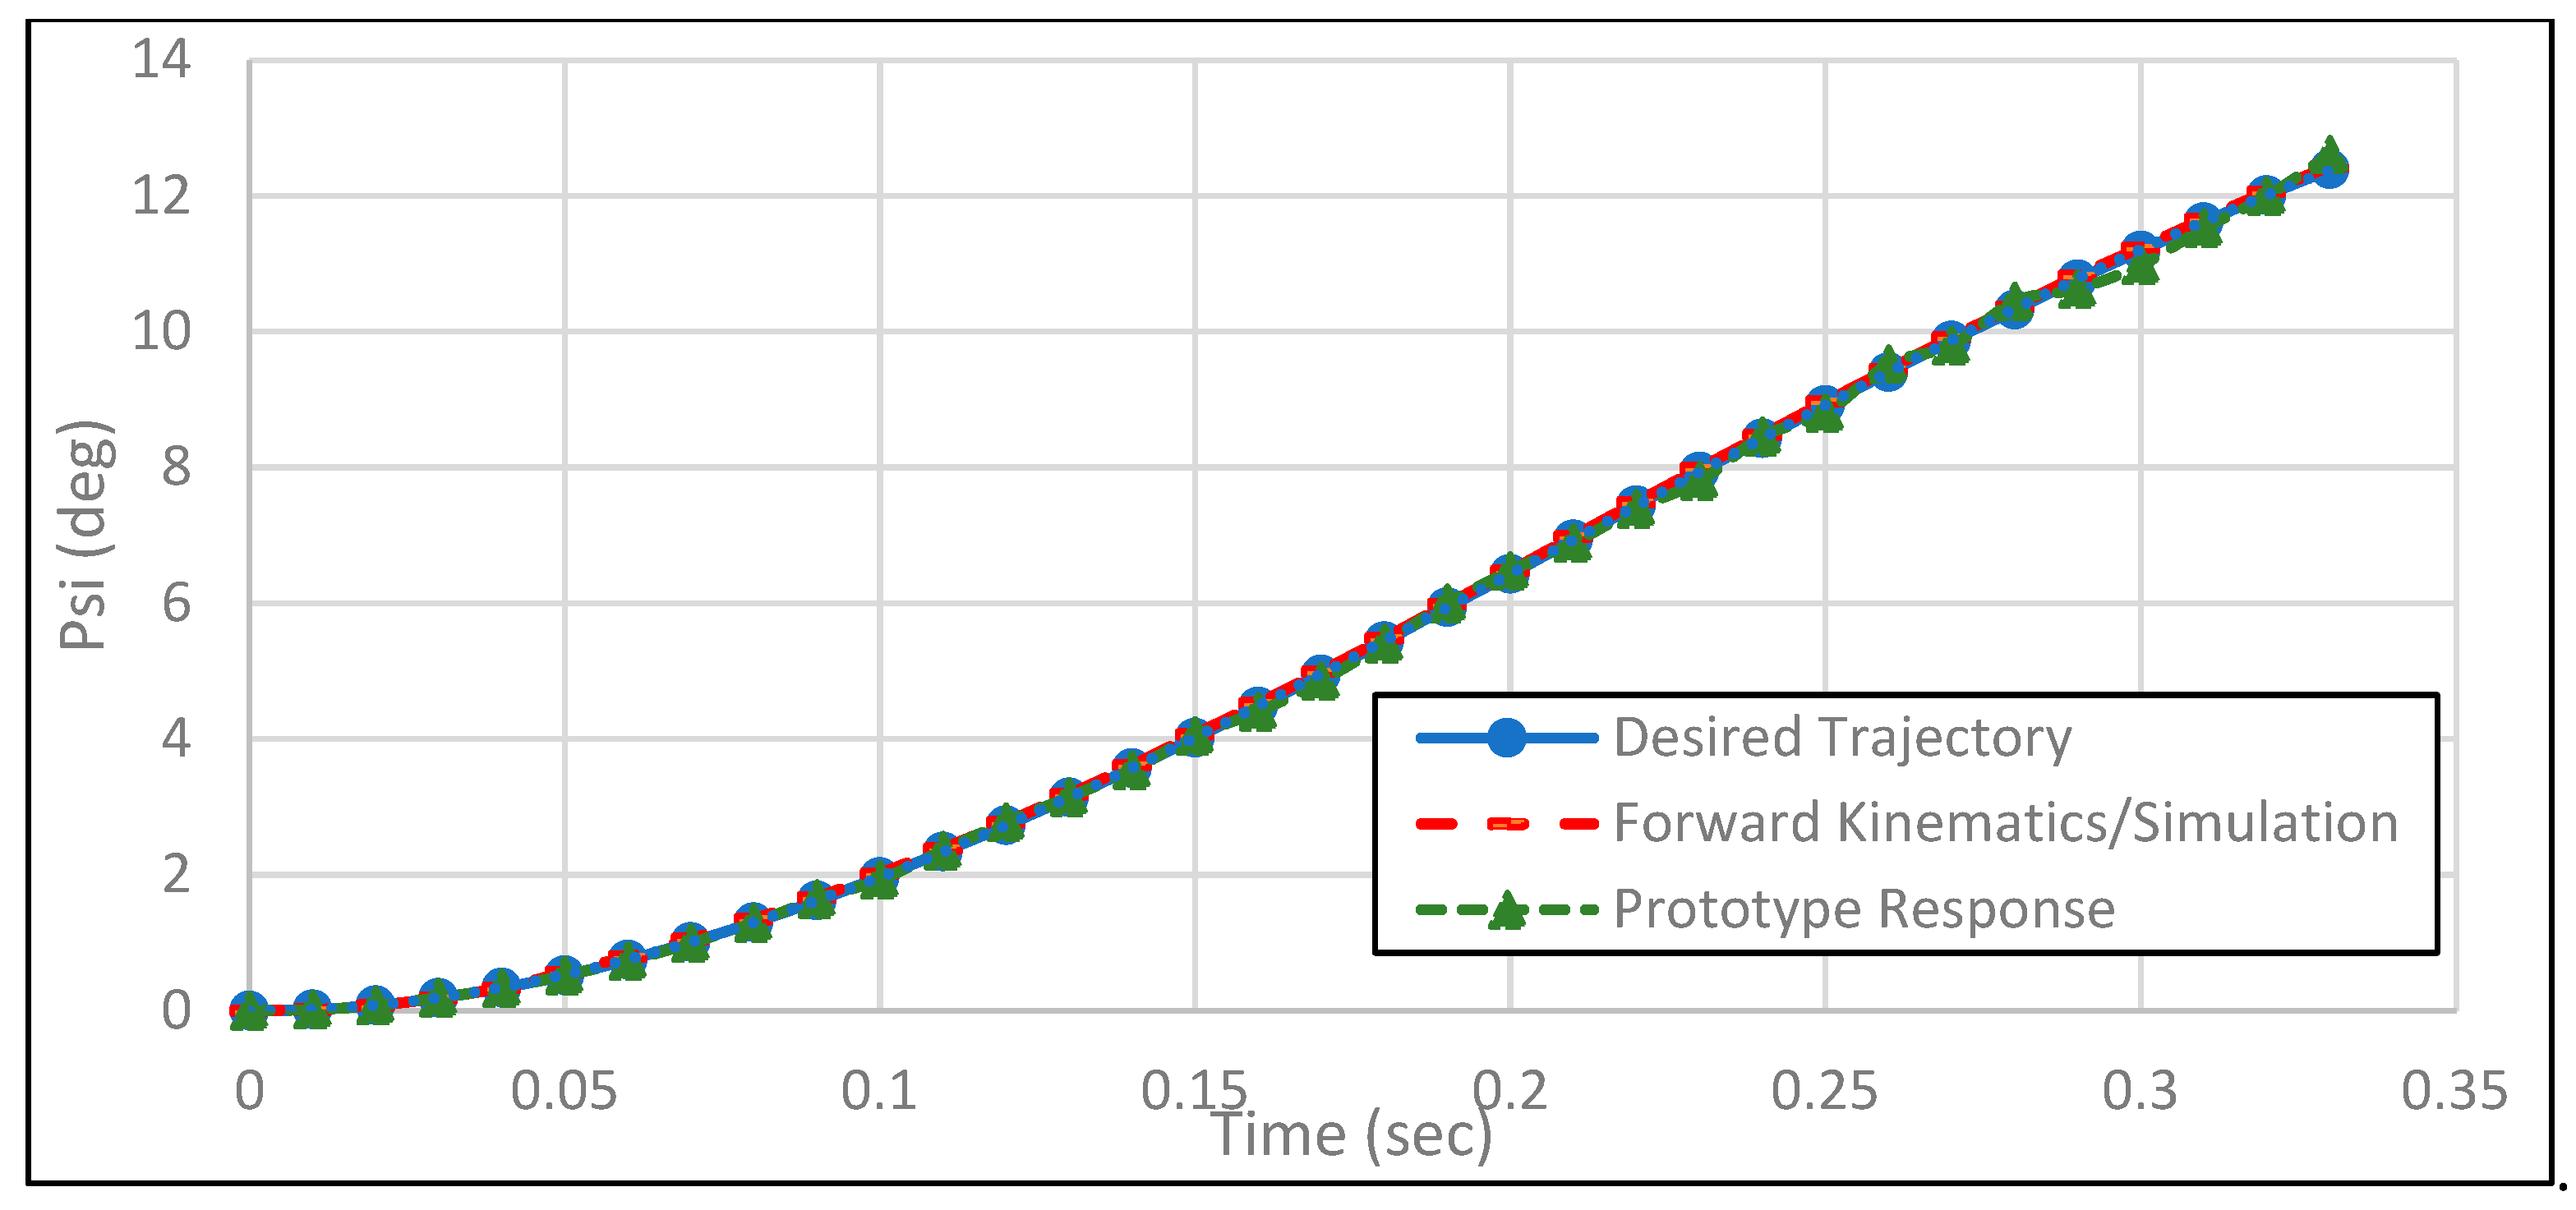
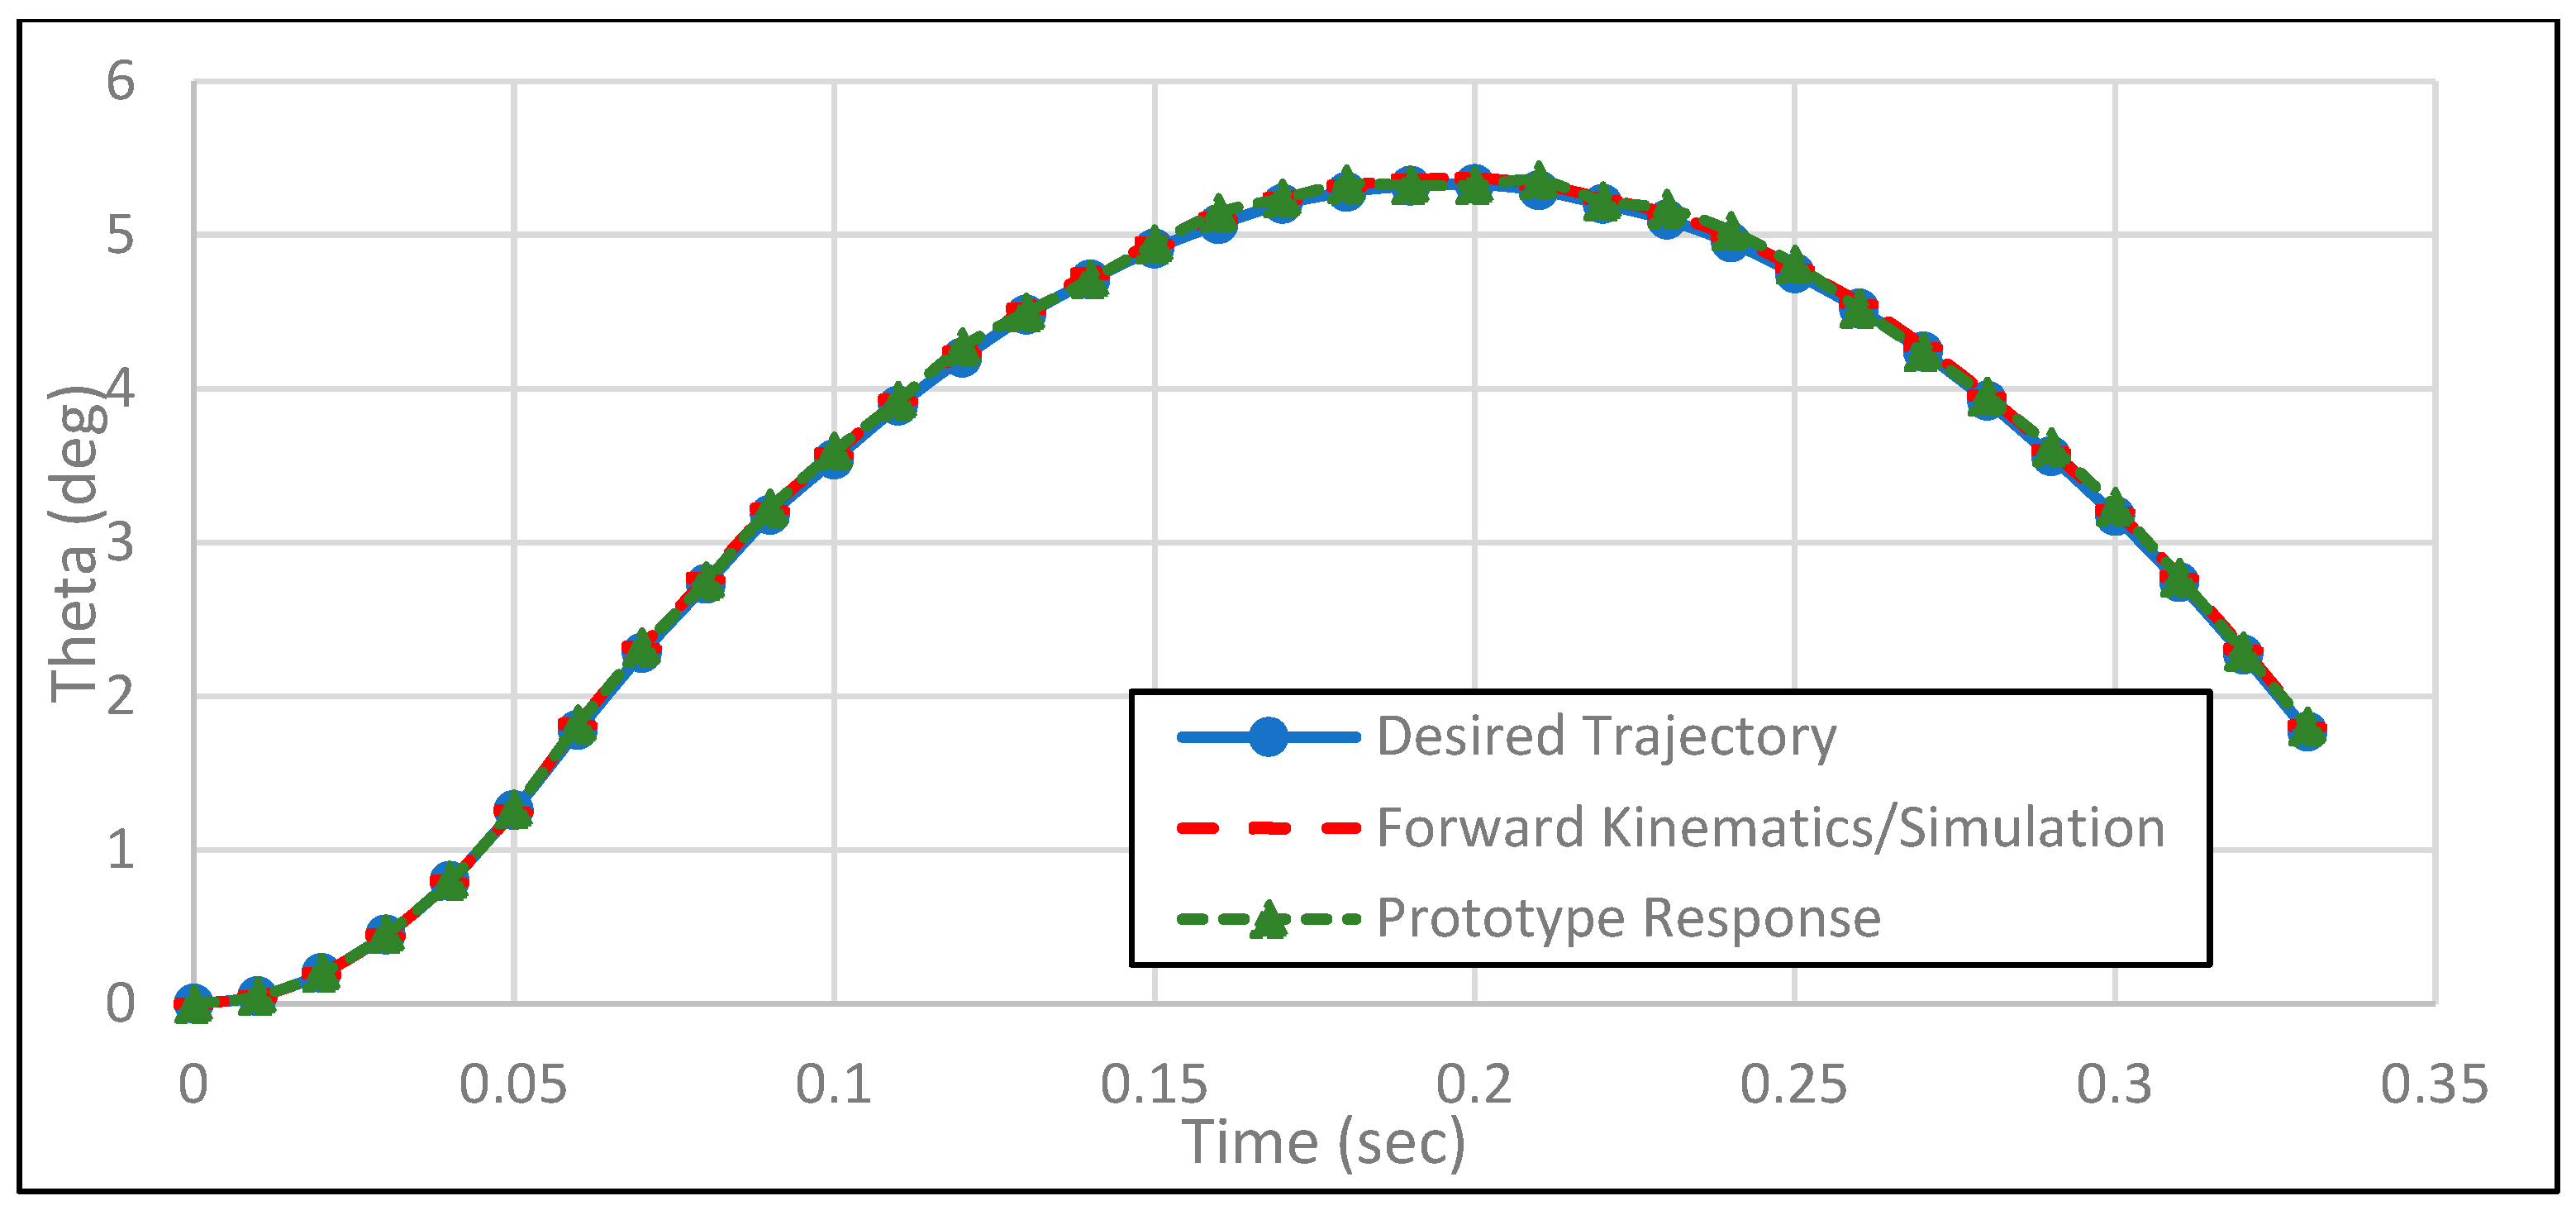
4.3. Trajectory Tracking Results
4.4. Quantitative Performance Evaluation and Repeatability Analysis
4.4.1. Repeatability Analysis
4.4.2. Tracking Performance Metrics
4.4.3. Motion Smoothness
5. Discussion
6. Conclusions
Author Contributions
Funding
Data Availability Statement
Conflicts of Interest
Abbreviations
| CTS | Captive Trajectory System |
| DH | Denavit–Hartenberg |
| DOF | Degrees of Freedom |
| ai | The offset distance between adjacent joint axes |
| di | The translational distance between incident normals |
| Joint Angle | |
| Twist Angle | |
| Psi | Yaw Angle |
| Theta | Pitch Angle |
| Phi | Roll Angle |
References
- Craig, J.J. Introduction to Robotics: Mechanics and Control, 3rd ed.; Pearson Prentice Hall: Upper Saddle River, NJ, USA, 2005. [Google Scholar]
- Spong, M.W.; Hutchinson, S.; Vidyasagar, M. Robot Modeling and Control, 1st ed.; John Wiley & Sons: New York, NY, USA, 2005. [Google Scholar]
- Iqbal, J.; Islam, M.R.U.; Khan, H. Modeling and analysis of a 6 DOF robotic arm manipulator. Can. J. Electr. Electron. Eng. 2012, 3, 300–306. [Google Scholar]
- Kumar, K.K.; Srinath, A.; Jugalanvesh, G.; Premsai, R.; Suresh, M. Kinematic analysis and simulation of 6 DOF Kuka KR5 robot for welding application. Int. J. Eng. Res. Appl. 2013, 3, 820–827. [Google Scholar]
- Singh, E.H.; Dhillon, N.; Ansari, E.I. Forward and inverse kinematics solution for six DOF with the help of robotics toolbox in MATLAB. Int. J. Appl. Innov. Eng. Manag. 2015, 4, 17–22. [Google Scholar]
- Alwardat, M.Y.; Alwan, H.M. Forward and Inverse Kinematics of a 6-DOF Robotic Manipulator with a Prismatic Joint Using MATLAB Robotics Toolbox. Int. J. Adv. Technol. Eng. Explor. 2024, 11, 1096–1110. [Google Scholar] [CrossRef] [Scilit]
- Stahl, W. Experimental Investigation of Store Separation Using CTS; AGARD Report No. AGARD-AR-330; NATO Science and Technology Organization: Neuilly-sur-Seine, France, 1995. [Google Scholar]
- Tomaro, R.F.; Smith, T.R.; Johnson, W.R. A Solution on the F/A-18C for Store Separation Using Wind Tunnel Testing. In Proceedings of the AIAA Aerospace Sciences Meeting and Exhibit, Reno, NV, USA, 11–14 January 1999. AIAA Paper 99-0122. [Google Scholar]
- Andrew, G.; Jay, N.; Roman, P. Design & Development of a New Captive Trajectory Simulation Model Support System. In Proceedings of the 35th Joint Propulsion Conference and Exhibit, Los Angeles, CA, USA, 20–24 June 1999. [Google Scholar]
- Garçon, F.; Taravel, P.; Raffin, J.-C. Recent Developments in Captive Trajectory Systems of the ONERA Modane Wind Tunnels. In Proceedings of the 39th Aerospace Sciences Meeting and Exhibit, Reno, NV, USA, 8–11 January 2001. [Google Scholar]
- Navair, A.C.; Md, P.R. Lessons Learned in 30 Years of Store Separation Testing. In Proceedings of the 47th AIAA Aerospace Sciences Meeting including The New Horizons Forum and Aerospace Exposition, Orlando, FL, USA, 5–8 January 2009. [Google Scholar]
- Carter, R.; Lind, R. Trajectory Optimization for Guided Store Separation. In Proceedings of the AIAA Guidance, Navigation, and Control Conference, Minneapolis, MN, USA, 13–16 August 2012. [Google Scholar]
- Huang, X.H.; Pang, X.D. Development of a New CTS System in a 1.2 m Transonic Wind Tunnel. J. Exp. Fluid Mech. 2008, 22, 95–98. [Google Scholar]
- Huang, X.H.; Luo, X.F. Design & Development of CTS System in FL-24 Wind Tunnel. Acta Aerodyn. Sin. 2008, 26, 145–149. [Google Scholar]
- Zhou, R.; Huang, X.; Zhang, Z.; Li, P. A captive trajectory system using double closed-loop velocity control. Acta Aeronaut. Astronaut. Sin. 2014, 35, 1522–1529. [Google Scholar] [CrossRef]
- Ran, W.; Binghui, C.; Jun, Z.; Chuanbao, S.; Xinlin, W. The design of a 3-DOF robot arm used for captive trajectory simulation in wind tunnel test. J. Exp. Fluid Mech. 2016, 30, 91–97. [Google Scholar]
- He, Y.; Zhang, F.L.; Xu, Z.G.; Liu, Z. Design Method of CTS for Wind Tunnel Experiment. Acta Armamentarii 2018, 39, 2480–2487. [Google Scholar] [CrossRef]
- Ishola, A.A.; Whidborne, J.F.; Tang, G. An Aircraft-Manipulator System for Virtual Flight Testing of Longitudinal Flight Dynamics. Robotics 2024, 13, 179. [Google Scholar] [CrossRef] [Scilit]
- Liu, C.K.; Negrut, D. The role of physics-based simulators in robotics. Annu. Rev. Control Robot. Auton. Syst. 2021, 4, 35–58. [Google Scholar] [CrossRef] [Scilit]
- Parhi, D.R.; Deepak, B.B.; Nayak, D.; Amrit, A. Forward and inverse kinematic models for an articulated robotic manipulator. Int. J. Artif. Intell. Comput. Res. 2012, 4, 103–109. [Google Scholar]
- Kucuk, S.; Bingul, Z. Robot Kinematics: Forward and Inverse Kinematics; IntechOpen: London, UK, 2006. [Google Scholar]
- Denavit, J.; Hartenberg, R.S. A kinematic notation for lower-pair mechanisms based on matrices. J. Appl. Mech. 1955, 22, 215–221. [Google Scholar] [CrossRef] [Scilit]
- Pieper, D.L. The Kinematics of Manipulators Under Computer Control. Ph.D. Dissertation, Stanford University, Stanford, CA, USA, 1968. [Google Scholar]
- Freudenstein, F. Design of mechanisms. Annu. Rev. Fluid Mech. 1973, 5, 457–486. [Google Scholar]
- Chen, P.; Liu, L.; Yu, F.; Li, H.; Yang, F.; Wang, X. A geometrical method for inverse kinematics of a kind of humanoid manipulator. Robot 2012, 34, 211. [Google Scholar] [CrossRef] [Scilit]
- Qassem, M.A.; Abuhadrous, I.; Elaydi, H. Modeling and simulation of 5 DOF educational robot arm. In Proceedings of the 2010 2nd International Conference on Advanced Computer Control, Shenyang, China, 27–29 March 2010; pp. 569–574. [Google Scholar]
- Wen, S.; Qin, G.; Zhang, B.; Lam, H.K.; Zhao, Y.; Wang, H. The study of model predictive control algorithm based on the force/position control scheme of the 5-DOF redundant actuation parallel robot. Robot. Auton. Syst. 2016, 79, 12–25. [Google Scholar] [CrossRef] [Scilit]
- Filiposka, M.; Djuric, A.M.; Elmaraghy, W. Kinematic analysis of a 6 DOF gantry machine. In SAE 2015 World Congress & Exhibition; SAE International: Warrendale, PA, USA, 2015; pp. 1–7. [Google Scholar]
- Chen, Q.; Zhu, S.; Zhang, X. Improved inverse kinematics algorithm using screw theory for a six-DOF robot manipulator. Int. J. Adv. Robot. Syst. 2015, 12, 140. [Google Scholar] [CrossRef] [Scilit]
- Raouf, I.; Lee, H.; Kim, H.S. Deep learning-based fault diagnosis of servo motor bearing using the attention-guided feature aggregation network. Expert Syst. Appl. 2024, 258, 125137. [Google Scholar] [CrossRef] [Scilit]
- Raouf, I.; Lee, H.; Kim, H.S. Mechanical fault detection based on machine learning for robotic RV reducer using electrical current signature analysis: A data-driven approach. J. Comput. Des. Eng. 2022, 9, 417–433. [Google Scholar] [CrossRef] [Scilit]
- Izaz, R.; Hyewon, L.; Yeong Rim, N.; Byeng, D.Y.; Heung Soo, K. Prognostic Health Management of the robotic Strain-Wave Gear Reducers based on variable speed of operation. J. Comput. Des. Eng. 2022, 9, 1775–1788. [Google Scholar]
- Izaz, R.; Prashant, K.; Salman, K.; Kim, H.S. Comprehensive Analysis of Current Developments, Challenges and Opportunities for Health Assessment of Smart Factory. Int. J. Precis. Eng. Manuf.-Green Tech. 2025, 12, 1321–1338. [Google Scholar]
- Fox, J.H. Generic Wing, Pylon, and Moving Finned Store; Technical Report No. TN 37389-6001; Arnold Engineering Development Center (AEDC): Tullahoma, TN, USA, 2000; pp. 535–554.
- Erdman, A.G. Mechanism Design and Synthesis, 2nd ed.; Prentice Hall: Englewood Cliffs, NJ, USA, 1991; Volume 1. [Google Scholar]
- Robertson, G.; Kumar, R. A Semi-Captive Trajectory System for the FSU Polysonic Wind Tunnel. In Proceedings of the 2018 AIAA Aerospace Sciences Meeting, AIAA 2018-0330, Kissimmee, FL, USA, 8–12 January 2018. [Google Scholar]
- Ji, Y.; Peng, M.; Lin, Q. Design of a wire-driven parallel robot for wind tunnel test based on the analysis of stiffness and workspace. Robotica 2024, 42, 3380–3397. [Google Scholar] [CrossRef] [Scilit]



| Joint/DH Parameters | Θ (deg) | α (deg) | d (mm) | a (mm) |
|---|---|---|---|---|
| 1 | 0 | −90 | 152 | 62 |
| 2 | −90 | 0 | 0 | 305 |
| 3 | 0 | 90 | 0 | 0 |
| 4 | 0 | −90 | −226.76 | 0 |
| 5 | 0 | 90 | 0 | 0 |
| 6 | 180 | 0 | −58.9 | 0 |
| Joints/Workspace Parameters | Joint 1 | Joint 2 | Joint 3 | Joint 4 | Joint 5 | Joint 6 |
|---|---|---|---|---|---|---|
| ROM (deg) | 360 | 130 | 140 | 360 | 360 | 360 |
| Length (mm) | 62 | 152 | 305 | 226.76 | 0 | 58.9 |
| Sr.# | Component | Description | Used for (Joint/Part) | Qty |
|---|---|---|---|---|
| 1. | Bearing | Rolling Wheel Bearing | Joint 1 | 02 |
| 2. | Bearing | Taper Wheel Bearing | Joint 2 | 03 |
| Joint 6 | ||||
| 3. | Bearing | Roller Bearing | Joint 3 | 01 |
| 4. | Bearing | Needle Roller Bearing | Joint 3 | 07 |
| Joint 4 | ||||
| Joint 5 | ||||
| Joint 6 | ||||
| 5. | Pulley | Timming Pulley | Joint 1 | 08 |
| Joint 3 | ||||
| Joint 4 | ||||
| Joint 5 | ||||
| 6. | Belt | Timming Belt | Between | 03 |
| Pulley 1 and 2, 3&4, 5&6, 7&8 | ||||
| 7. | Stepper Motor | NEMA 17 with Gearbox and Magnetic Encoder | Joint 1 | 04 |
| Joint 4 | ||||
| Joint 5 | ||||
| Joint 6 | ||||
| 8. | Stepper Motor | NEMA 23 with Gearbox and Magnetic Encoder | Joint 2 | 05 |
| Joint 3 | ||||
| 9. | Microcontroller | Arduino Uno | Main Control Unit | 01 |
| 10. | Motor Drivers | TB6600 | Joint 2 | 02 |
| Joint 3 | ||||
| A4988 | Joint 1 | 04 | ||
| Joint 4 | ||||
| Joint 5 | ||||
| Joint 6 | ||||
| 11. | Miscellaneous Components | Washers, Spacers, Screws, Locknuts, etc. | Various joints and parts | Multiple |
| Variable | Mean Error | Standard Deviation | CV (%) |
|---|---|---|---|
| X Position (mm) | 1.42 | 0.010 | 0.70 |
| Y Position (mm) | 1.18 | 0.008 | 0.68 |
| Z Position (mm) | 1.35 | 0.009 | 0.67 |
| Roll (deg) | 0.82 | 0.006 | 0.73 |
| Pitch (deg) | 0.95 | 0.009 | 0.95 |
| Yaw (deg) | 0.88 | 0.007 | 0.79 |
| Component | RMSE | IAE | ISE | ITAE |
|---|---|---|---|---|
| X Position (mm) | 1.37 | 18.6 | 32.4 | 112.5 |
| Y Position (mm) | 1.12 | 15.2 | 24.8 | 97.1 |
| Z Position (mm) | 1.28 | 17.3 | 29.7 | 108.4 |
| Roll (deg) | 0.79 | 9.4 | 6.1 | 58.3 |
| Pitch (deg) | 0.91 | 11.2 | 8.4 | 66.9 |
| Yaw (deg) | 0.84 | 10.1 | 7.2 | 61.7 |
| Metric | Value |
|---|---|
| Mean velocity variation | 3.2% |
| Peak jerk | 0.84 m/s3 |
| RMS jerk | 0.31 m/s3 |
| Study | System Architecture | DOF | Methodology | Validation | Quantitative Metrics | Application |
|---|---|---|---|---|---|---|
| 3-DOF CTS Robot Arm [16] | Serial robotic manipulator | 3 | Numerical inverse kinematics for trajectory positioning | Simulation and design verification | Limited trajectory accuracy evaluation | CTS model positioning in wind tunnel |
| CTS Design Framework [17] | Mechanical CTS trajectory rig | Multi-axis | System-level CTS trajectory design methodology | Simulation and wind-tunnel testing | Not reported | Captive trajectory simulation |
| Aircraft–Manipulator Framework [18] | Serial manipulator with aircraft model | 3 | Numerical inverse kinematics with PID trajectory tracking | Simulation | Limited trajectory comparison | Virtual flight testing |
| Semi-CTS [36] | Mechanical CTS positioning rig | Multi-axis | Mechanical reproduction of predefined store trajectory | Wind-tunnel experiments | Not reported | Aerodynamic store separation testing |
| Wire-Driven Parallel Robot [37] | Cable-driven parallel robot | 6 | Cable-driven kinematic modeling with workspace analysis | Prototype wind-tunnel system | Limited positioning evaluation | Robotic model positioning |
| Proposed ROBO-S | Serial manipulator | 6 | Closed-form DH-based kinematic modeling with analytical inverse kinematics | Prototype hardware experiments | RMSE, IAE, ISE, ITAE, repeatability, smoothness | CTS store separation trajectory execution |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Sadiq, S.; Sohail, M.U.; Wasim, M.; Ullah, F.K.; Khan, Z. Design and Verification of 6-DOF Robotic Arm for Captive Trajectory System Applications in Wind Tunnel. Automation 2026, 7, 58. https://doi.org/10.3390/automation7020058
Sadiq S, Sohail MU, Wasim M, Ullah FK, Khan Z. Design and Verification of 6-DOF Robotic Arm for Captive Trajectory System Applications in Wind Tunnel. Automation. 2026; 7(2):58. https://doi.org/10.3390/automation7020058
Chicago/Turabian StyleSadiq, Sadia, Muhammad Umer Sohail, Muhammad Wasim, Farooq Kifayat Ullah, and Zeashan Khan. 2026. "Design and Verification of 6-DOF Robotic Arm for Captive Trajectory System Applications in Wind Tunnel" Automation 7, no. 2: 58. https://doi.org/10.3390/automation7020058
APA StyleSadiq, S., Sohail, M. U., Wasim, M., Ullah, F. K., & Khan, Z. (2026). Design and Verification of 6-DOF Robotic Arm for Captive Trajectory System Applications in Wind Tunnel. Automation, 7(2), 58. https://doi.org/10.3390/automation7020058