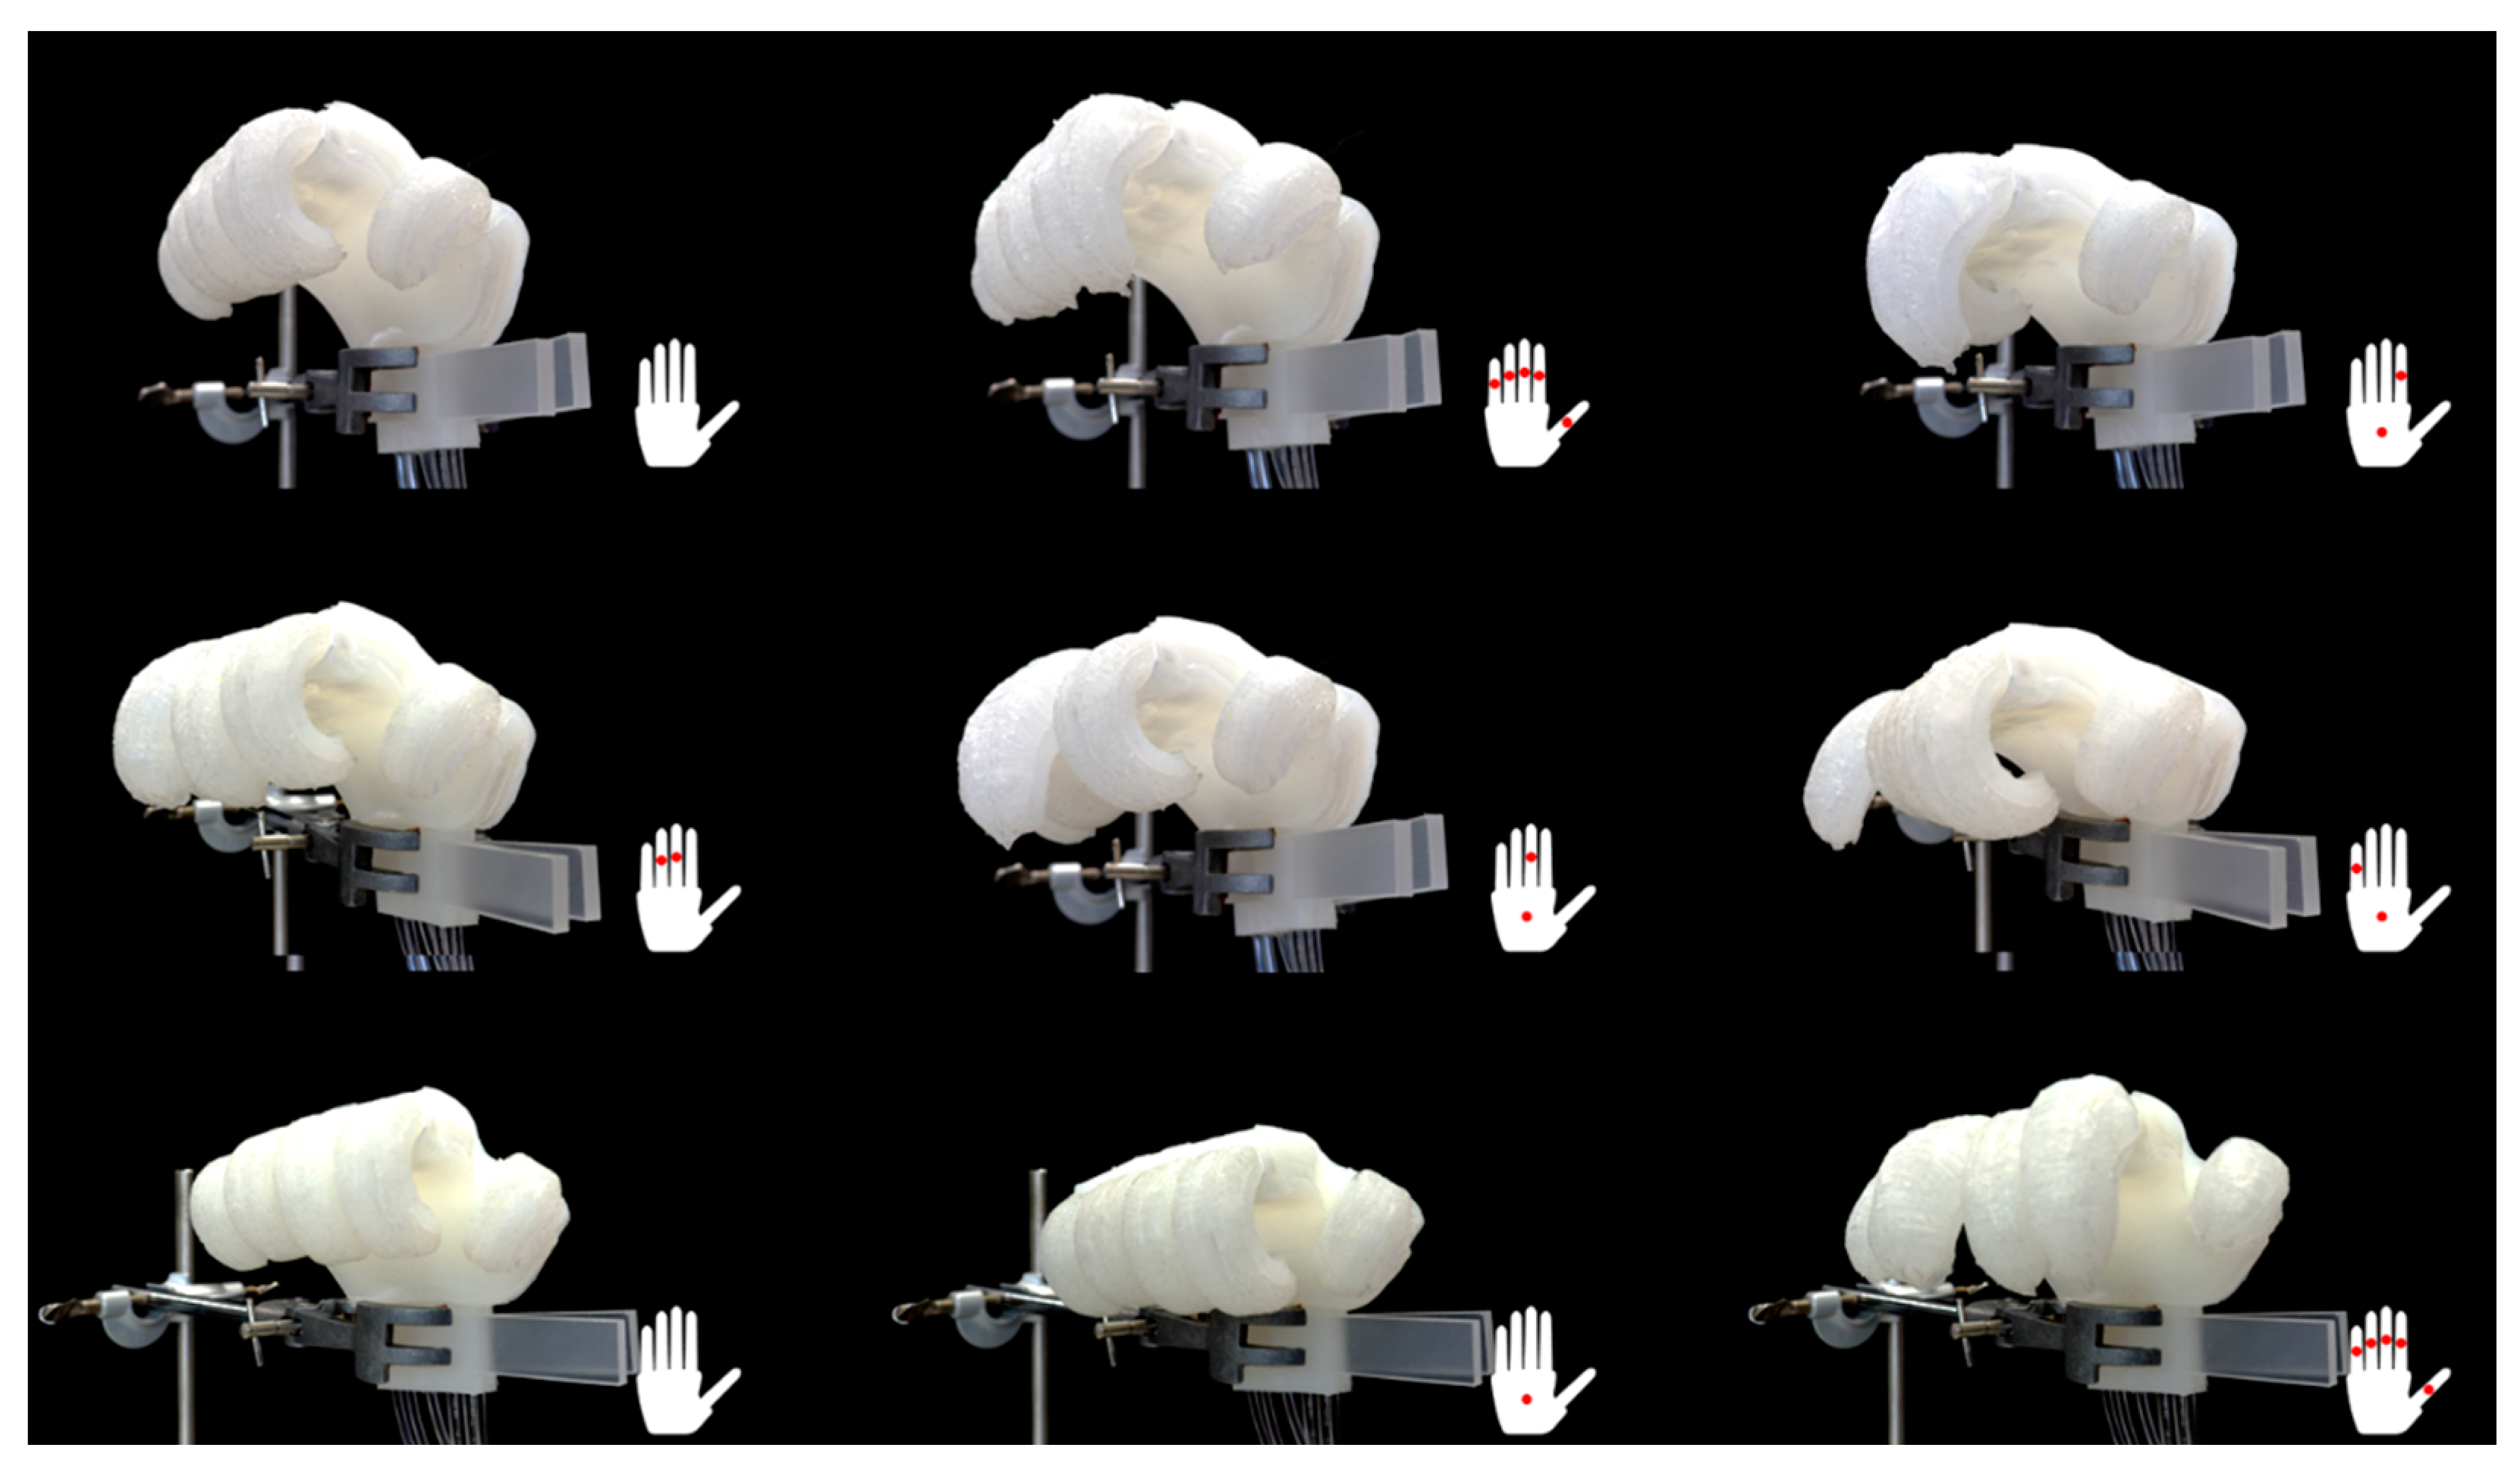
Improved Anthropomorphic Robotic Hand for Architecture and Construction: Integrating Prestressed Mechanisms with Self-Healing Elastomers

Abstract
Share and Cite
Kim, M.; Yaesmin, R.; Seo, H.; Yi, H. Improved Anthropomorphic Robotic Hand for Architecture and Construction: Integrating Prestressed Mechanisms with Self-Healing Elastomers. Biomimetics 2025, 10, 284. https://doi.org/10.3390/biomimetics10050284
Kim M, Yaesmin R, Seo H, Yi H. Improved Anthropomorphic Robotic Hand for Architecture and Construction: Integrating Prestressed Mechanisms with Self-Healing Elastomers. Biomimetics. 2025; 10(5):284. https://doi.org/10.3390/biomimetics10050284
Chicago/Turabian StyleKim, Mijin, Rubaya Yaesmin, Hyungtak Seo, and Hwang Yi. 2025. "Improved Anthropomorphic Robotic Hand for Architecture and Construction: Integrating Prestressed Mechanisms with Self-Healing Elastomers" Biomimetics 10, no. 5: 284. https://doi.org/10.3390/biomimetics10050284
APA StyleKim, M., Yaesmin, R., Seo, H., & Yi, H. (2025). Improved Anthropomorphic Robotic Hand for Architecture and Construction: Integrating Prestressed Mechanisms with Self-Healing Elastomers. Biomimetics, 10(5), 284. https://doi.org/10.3390/biomimetics10050284