Article

Research on Variable-Universe Fuzzy Control Technology of an Electro-Hydraulic Hitch System
1
College of Transportation, Shandong University of Science and Technology, Qingdao 266590, China
2
College of Mechanical and Electronic Engineering, Shandong University of Science and Technology, Qingdao 266590, China
3
School of Mechanical and Automotive Engineering, Qilu University of Technology, Jinan 250353, China
*
Author to whom correspondence should be addressed.
Processes 2021, 9(11), 1920; https://doi.org/10.3390/pr9111920
Submission received: 30 August 2021 / Revised: 19 October 2021 / Accepted: 21 October 2021 / Published: 27 October 2021
(This article belongs to the Special Issue Synergies in Combined Development of Processes and Models)

Abstract

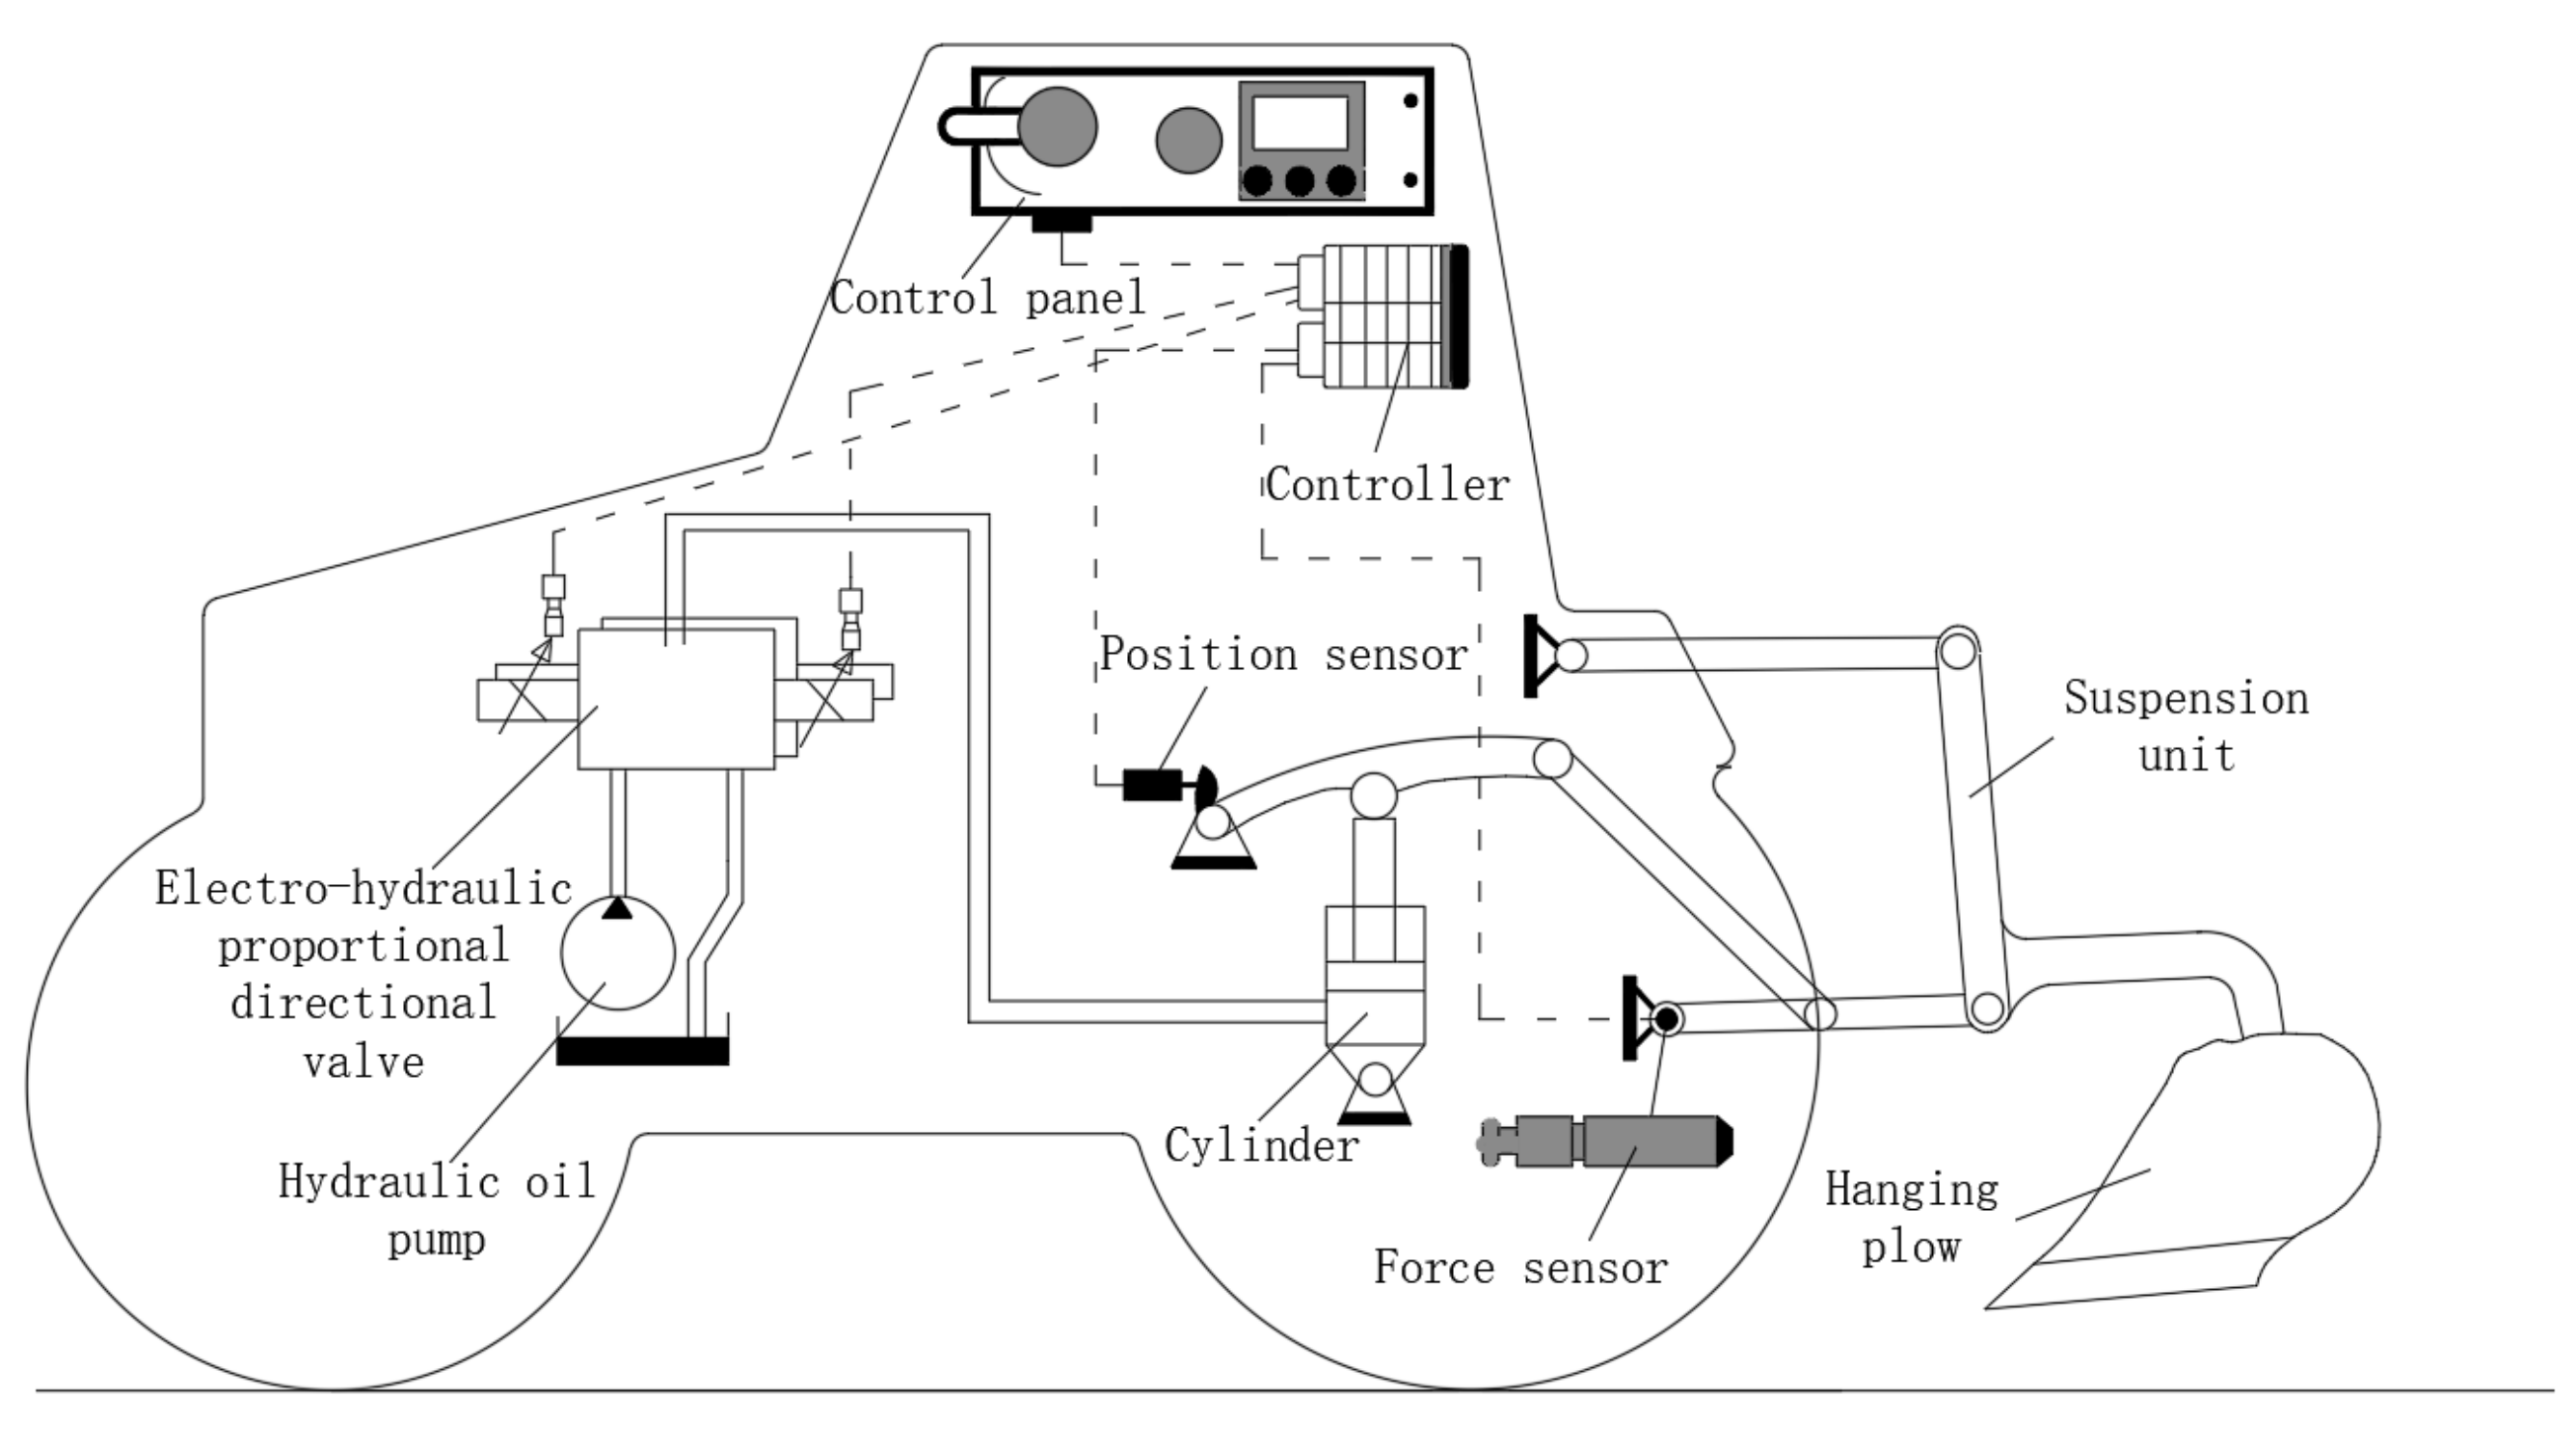
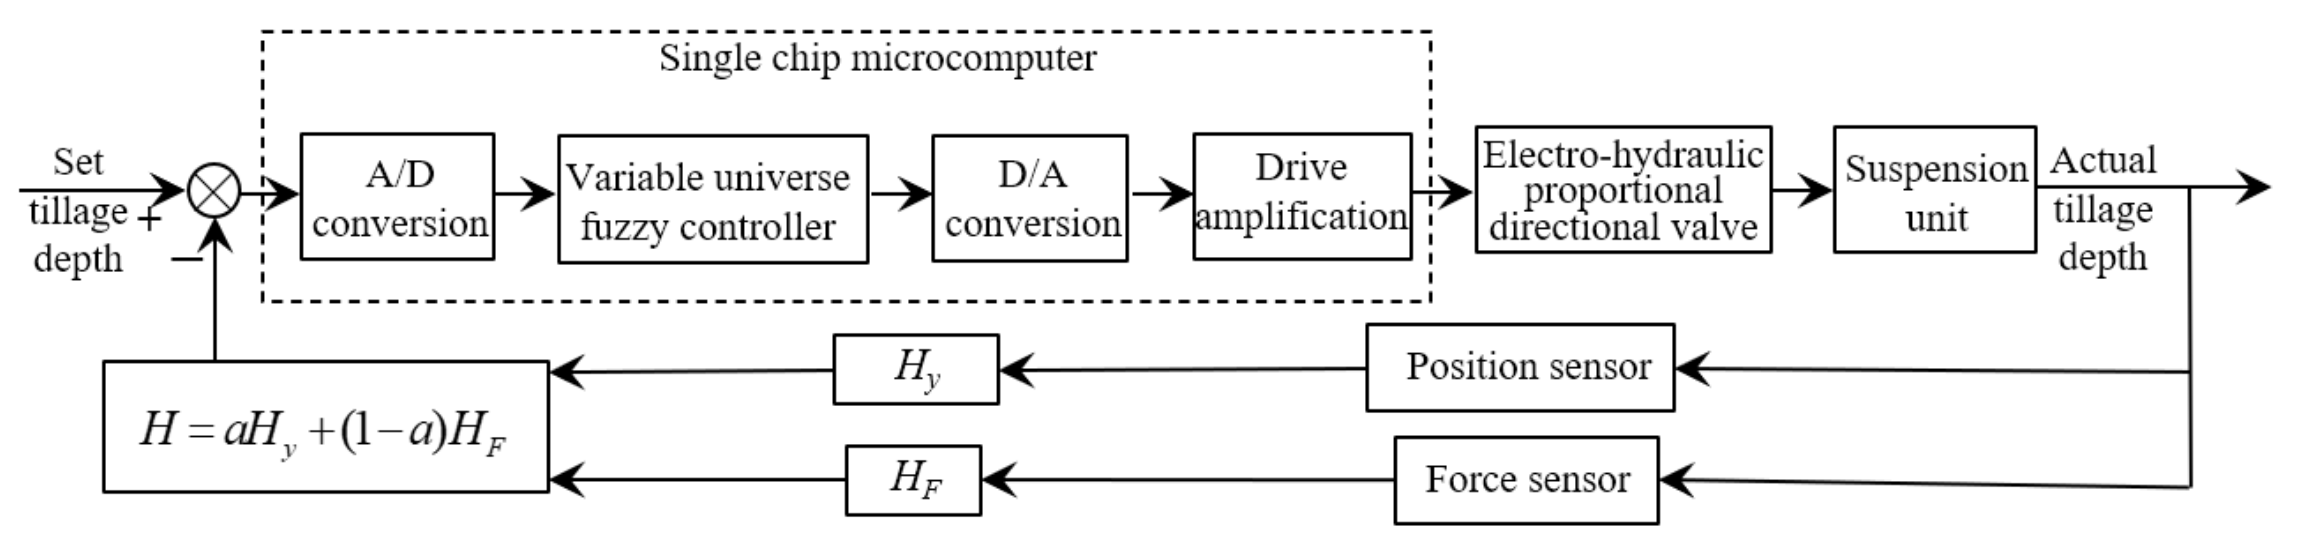
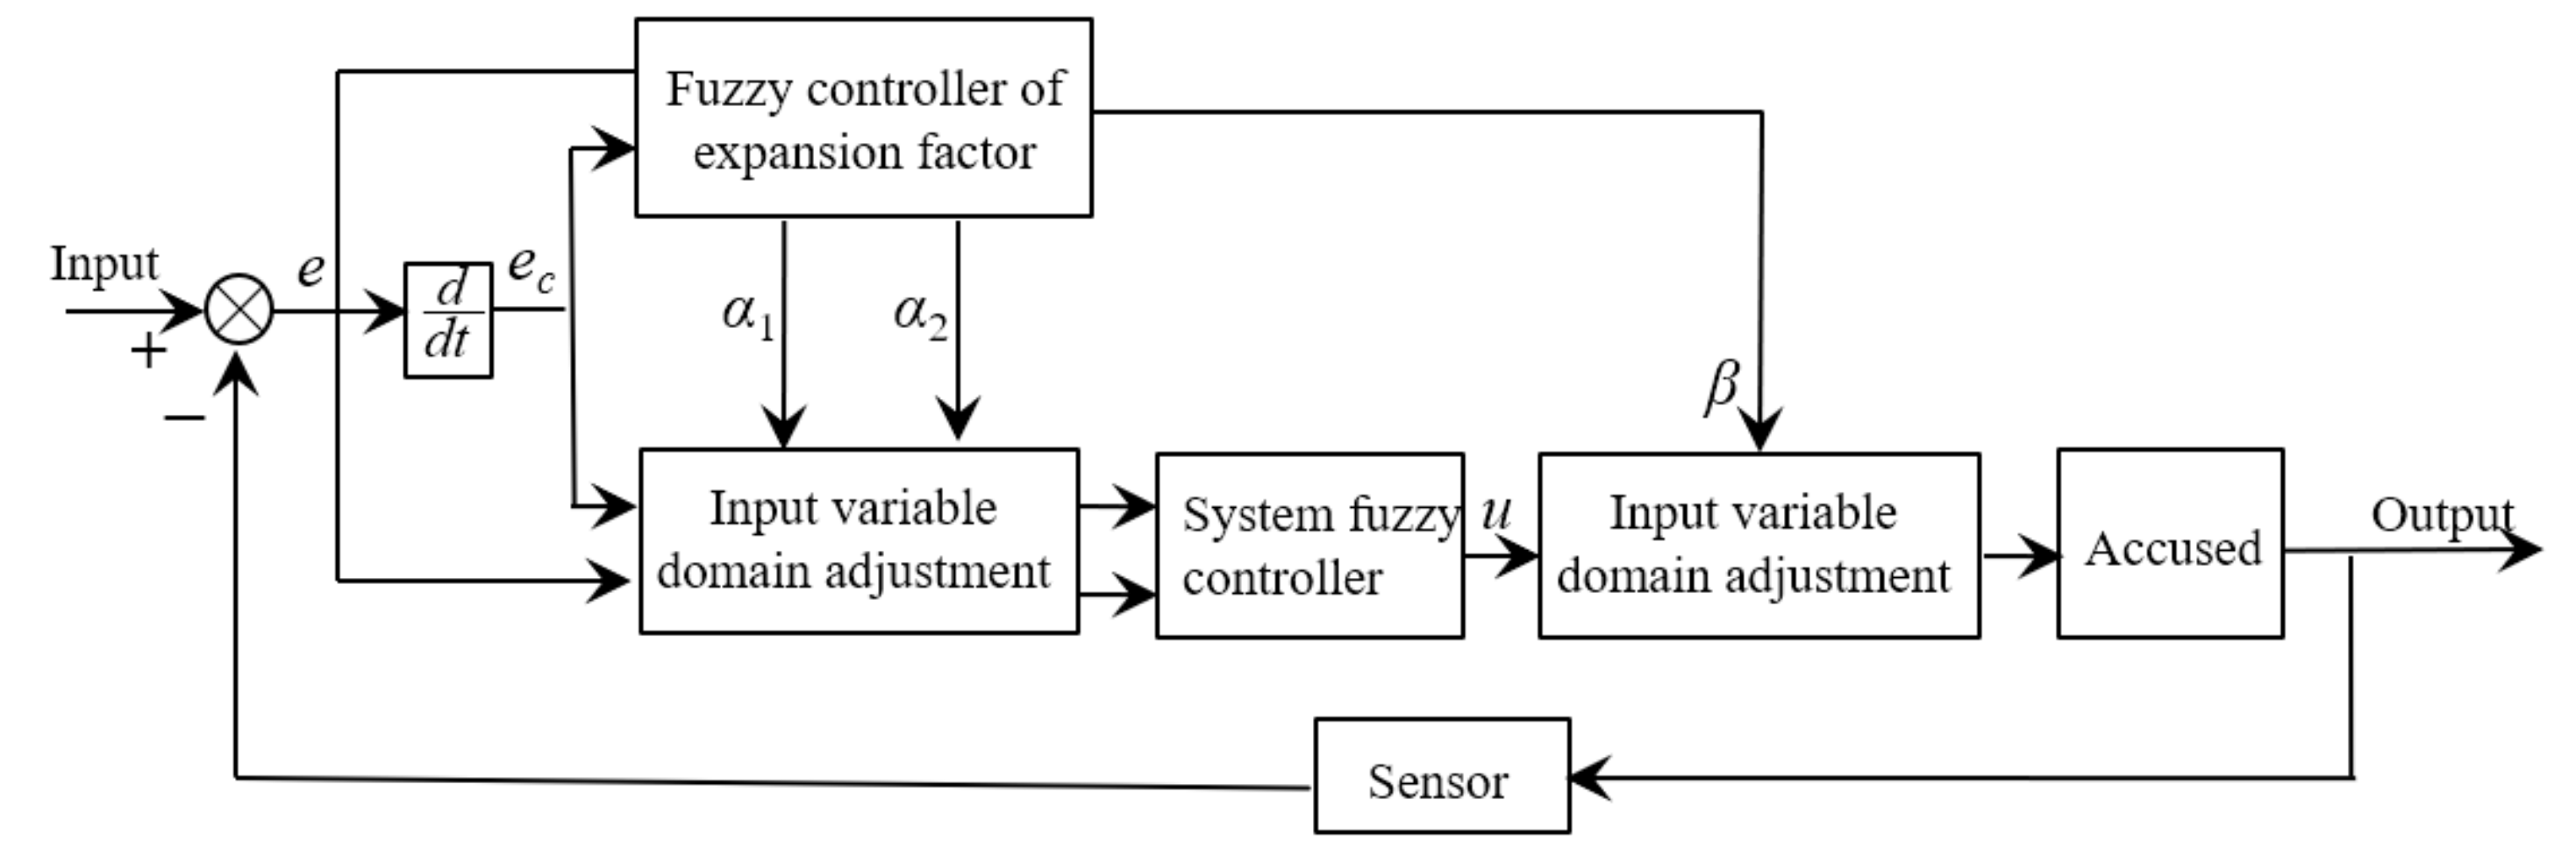
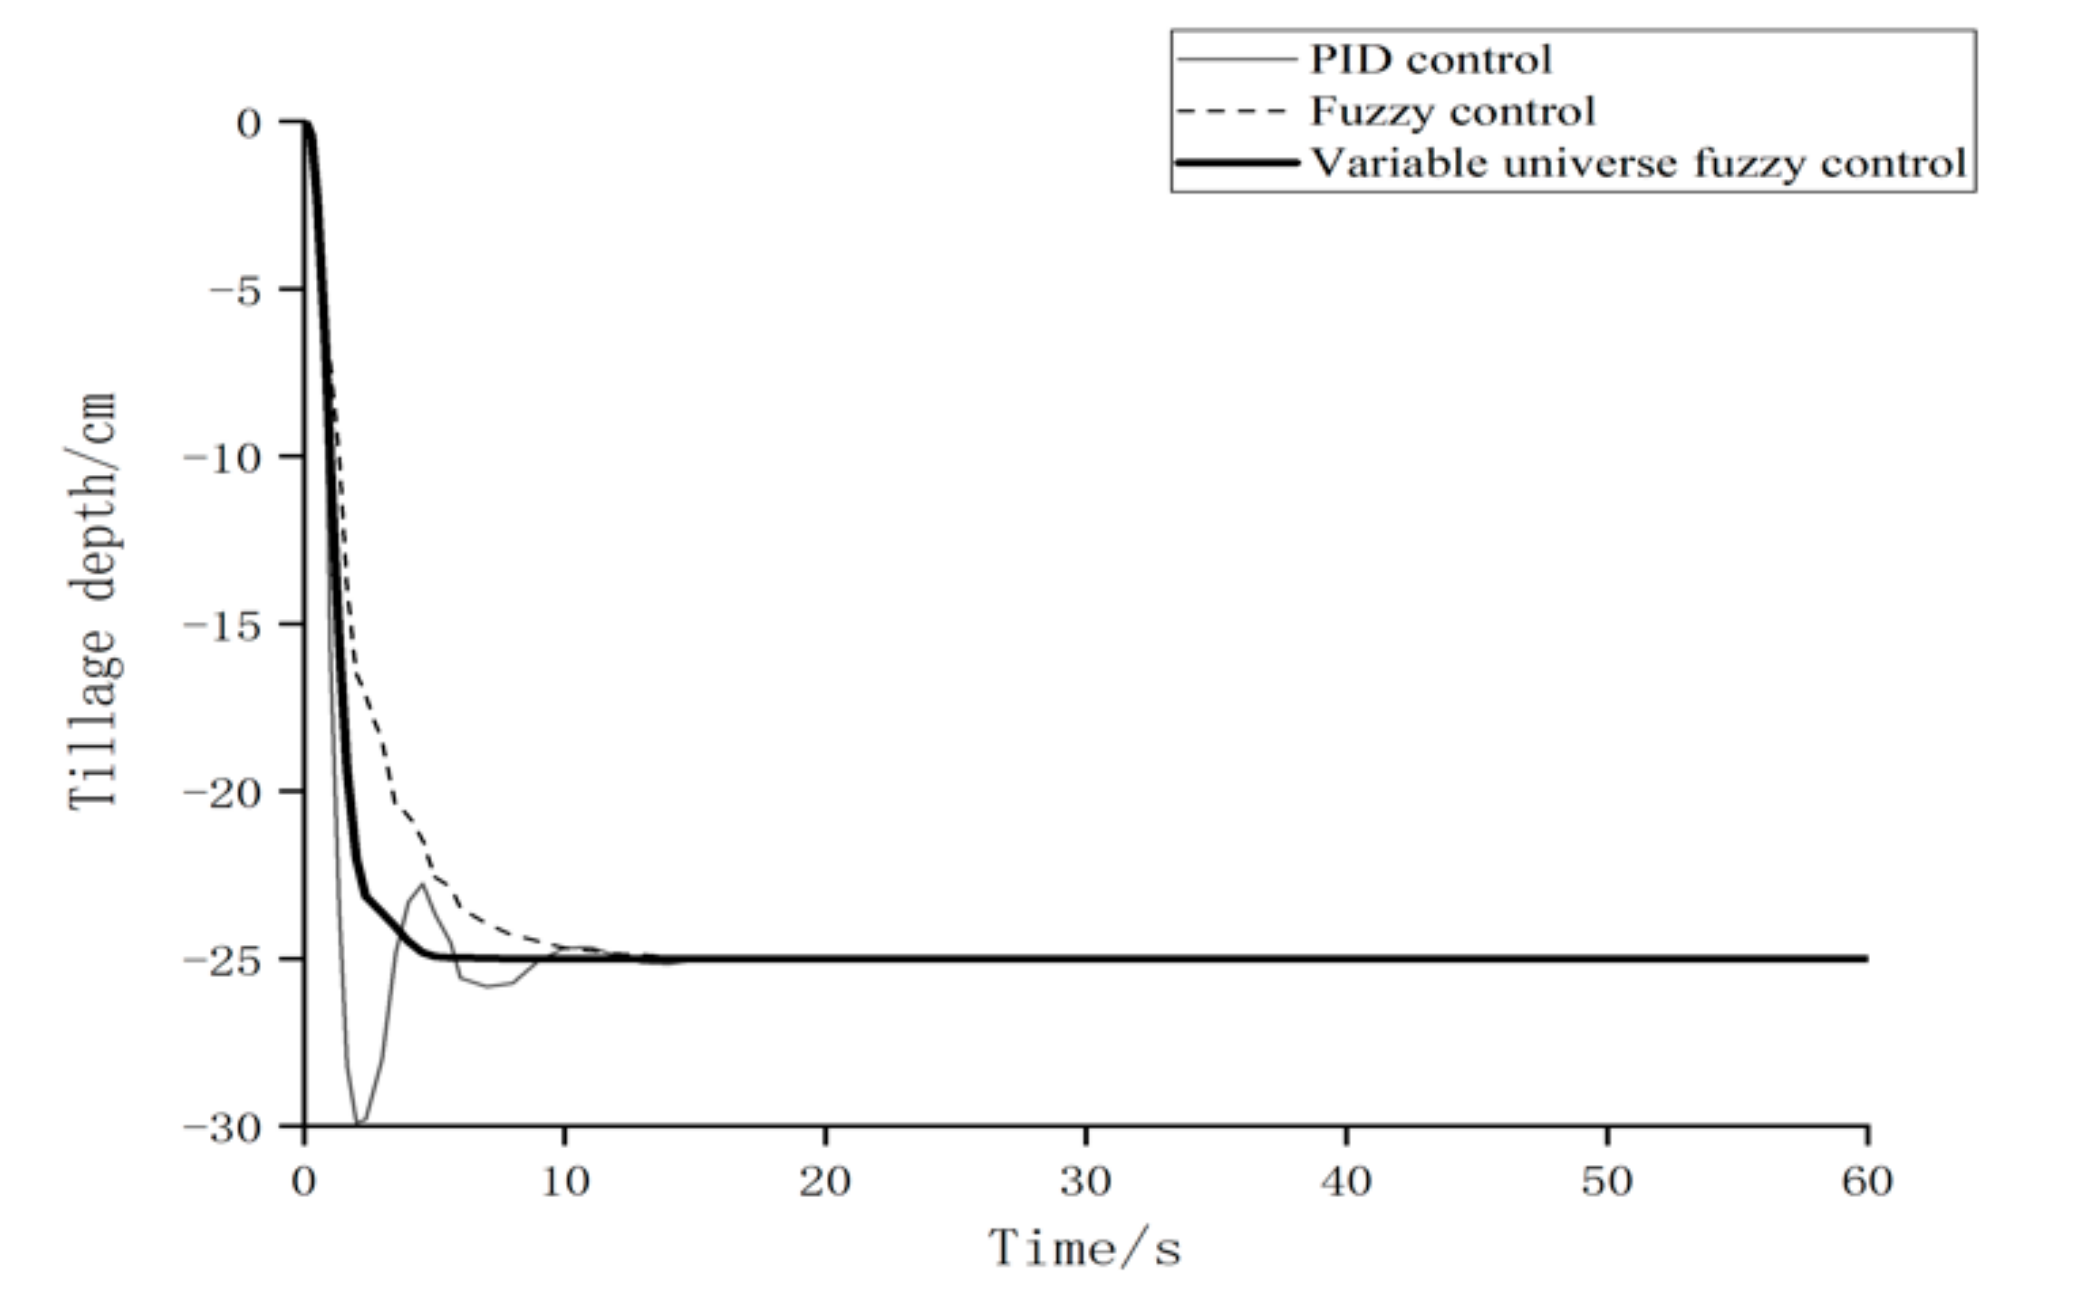
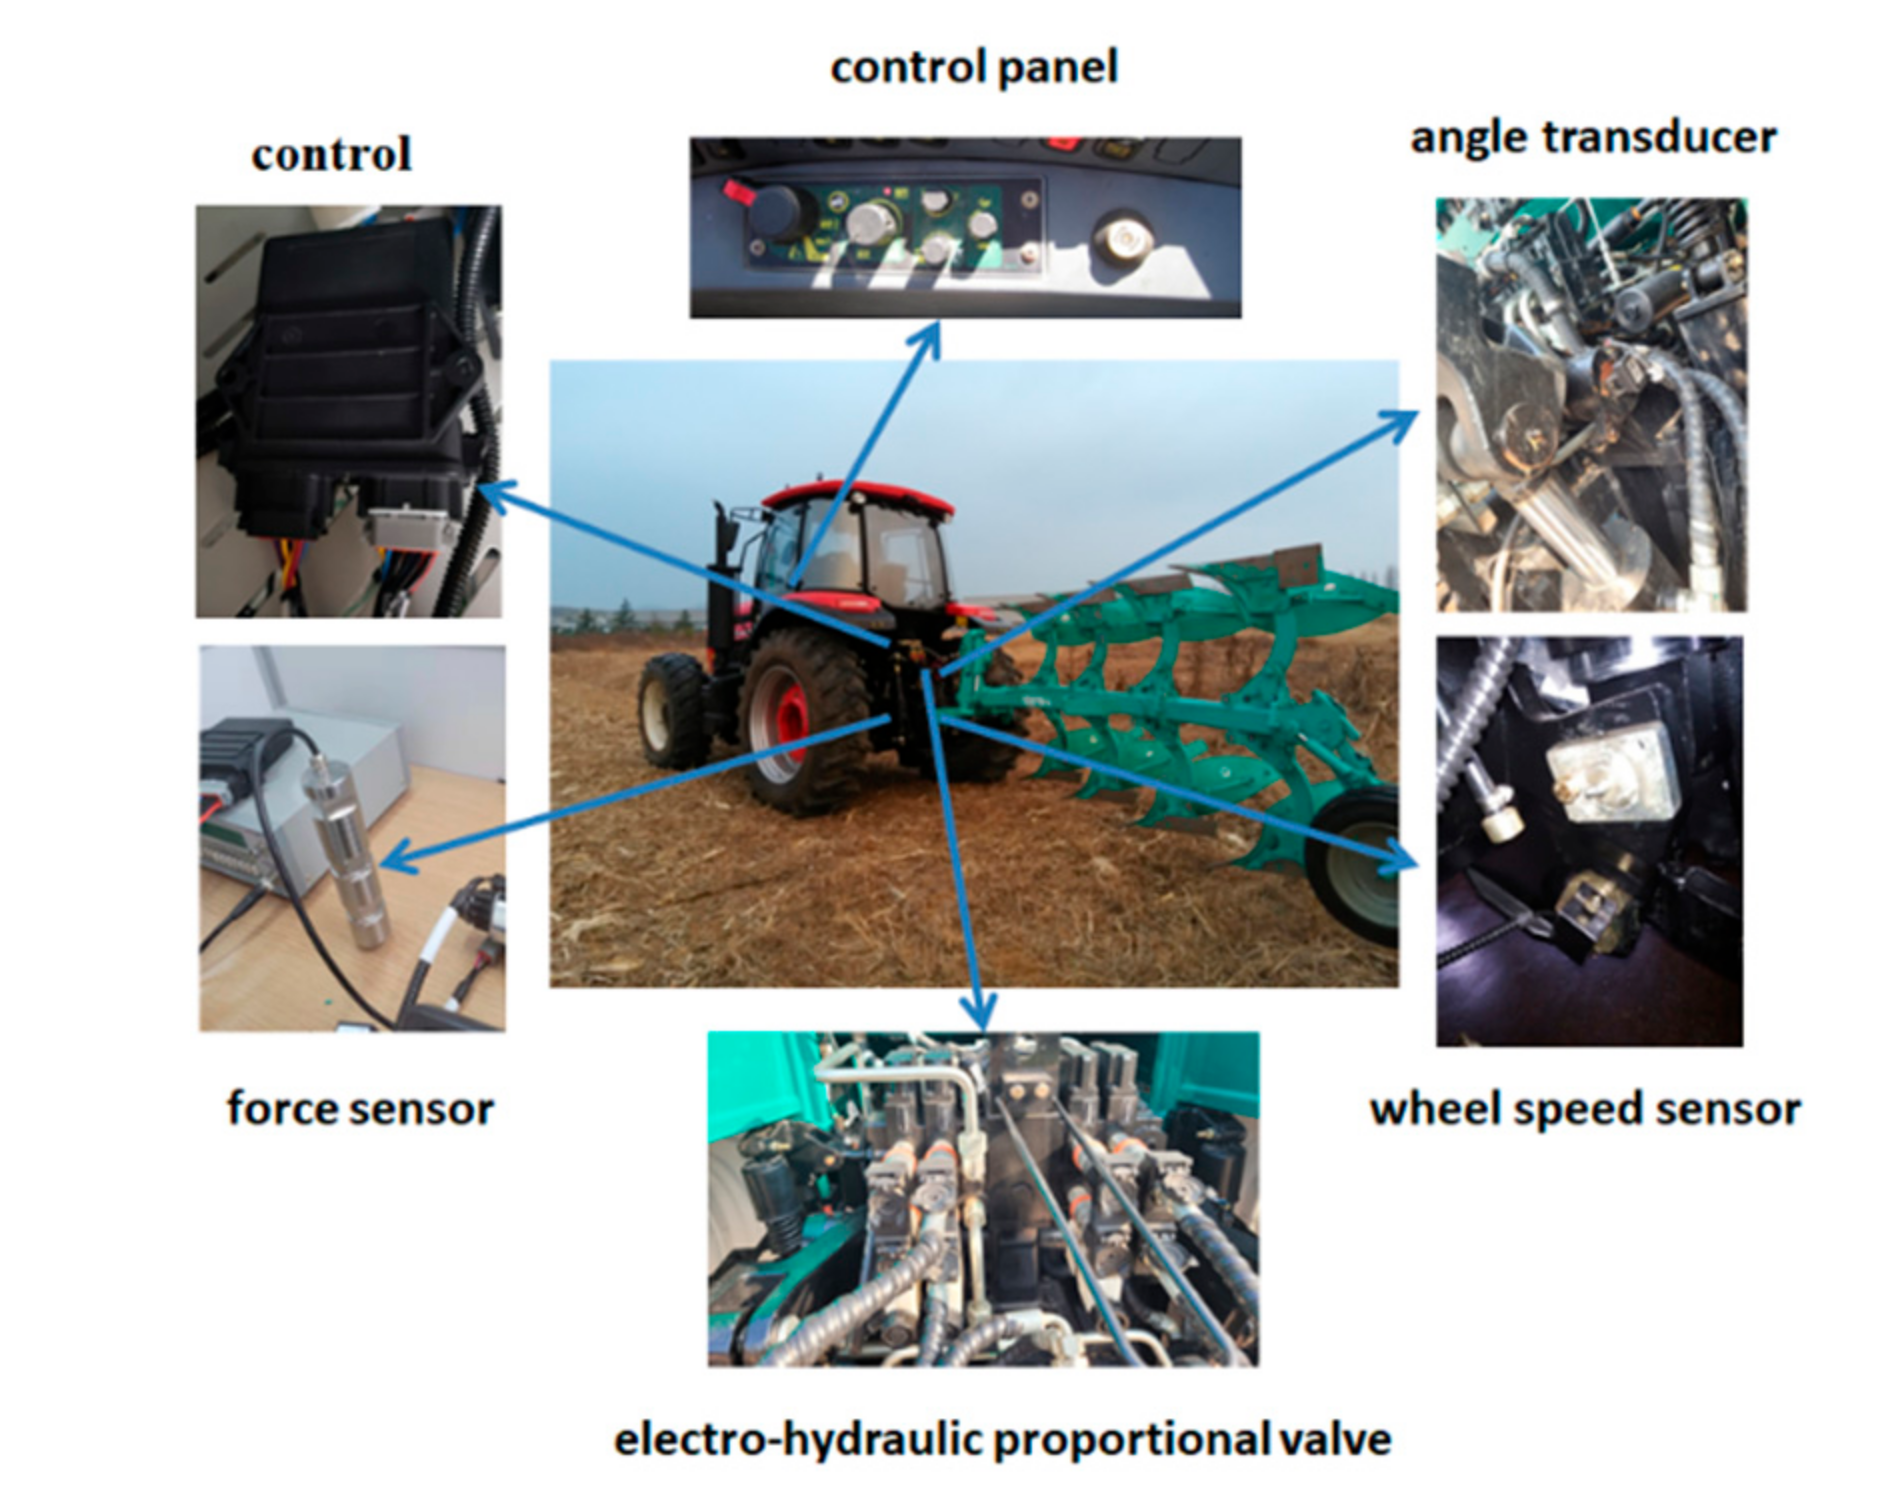
To improve the quality and control accuracy of the farming tractor electro-hydraulic hitch system, a variable-universe fuzzy control algorithm is introduced herein based on force–position mixed adjustment. (1) Background: This research sought to improve the operation quality and control precision of the tractor electro-hydraulic suspension operation system by solving the slow response and low precision problems in the target value control of the system. (2) Methods: According to the characteristics of the operating system, the working principle is discussed. The variable-universe fuzzy controller and the control module were designed based on MC9S12XS128. At the same time, we used Matlab/Simulink to study the step response, and field tests were carried out based on the existing test conditions. (3) Results: In the response stage, the variable-universe fuzzy control only needs 5.85 s, and there is no overshoot problem; in the normal tillage stage, the maximum tillage depth difference is only 1.6 cm, and the traction force is 428 N, which is closer to the expected value. (4) Conclusions: The farming quality and efficiency of the operating system were improved. Additionally, the operating system can also provide technical support for intelligent agricultural machinery and the field management mode in the future.
Keywords: electro-hydraulic hitch system; variable domain fuzzy; single-chip microcomputer; software and hardware design; test electro-hydraulic hitch system; variable domain fuzzy; single-chip microcomputer; software and hardware design; test