Adaptive Prescribed-Time Bounded Consensus Tracking for Nonlinear Multi-Agent Systems with Actuator Faults


Abstract
1. Introduction
- A PT bounded stability criterion is derived by means of a smooth scaling function that remains finite over the entire operation interval. Unlike PT formulations involving singular time-varying terms, the resulting Lyapunov condition yields an explicit-form residual estimate after the prescribed time and facilitates the subsequent fault-tolerant controller construction.
- A distributed adaptive fault-tolerant control architecture is formulated for high-order nonlinear agents affected by actuator failures and unmatched perturbations. Neural approximators are incorporated to compensate for unknown nonlinear terms, adaptive laws are designed to accommodate actuator fault effects, and finite-time differentiators are introduced to eliminate the need for repeatedly differentiating virtual controllers in the recursive design.
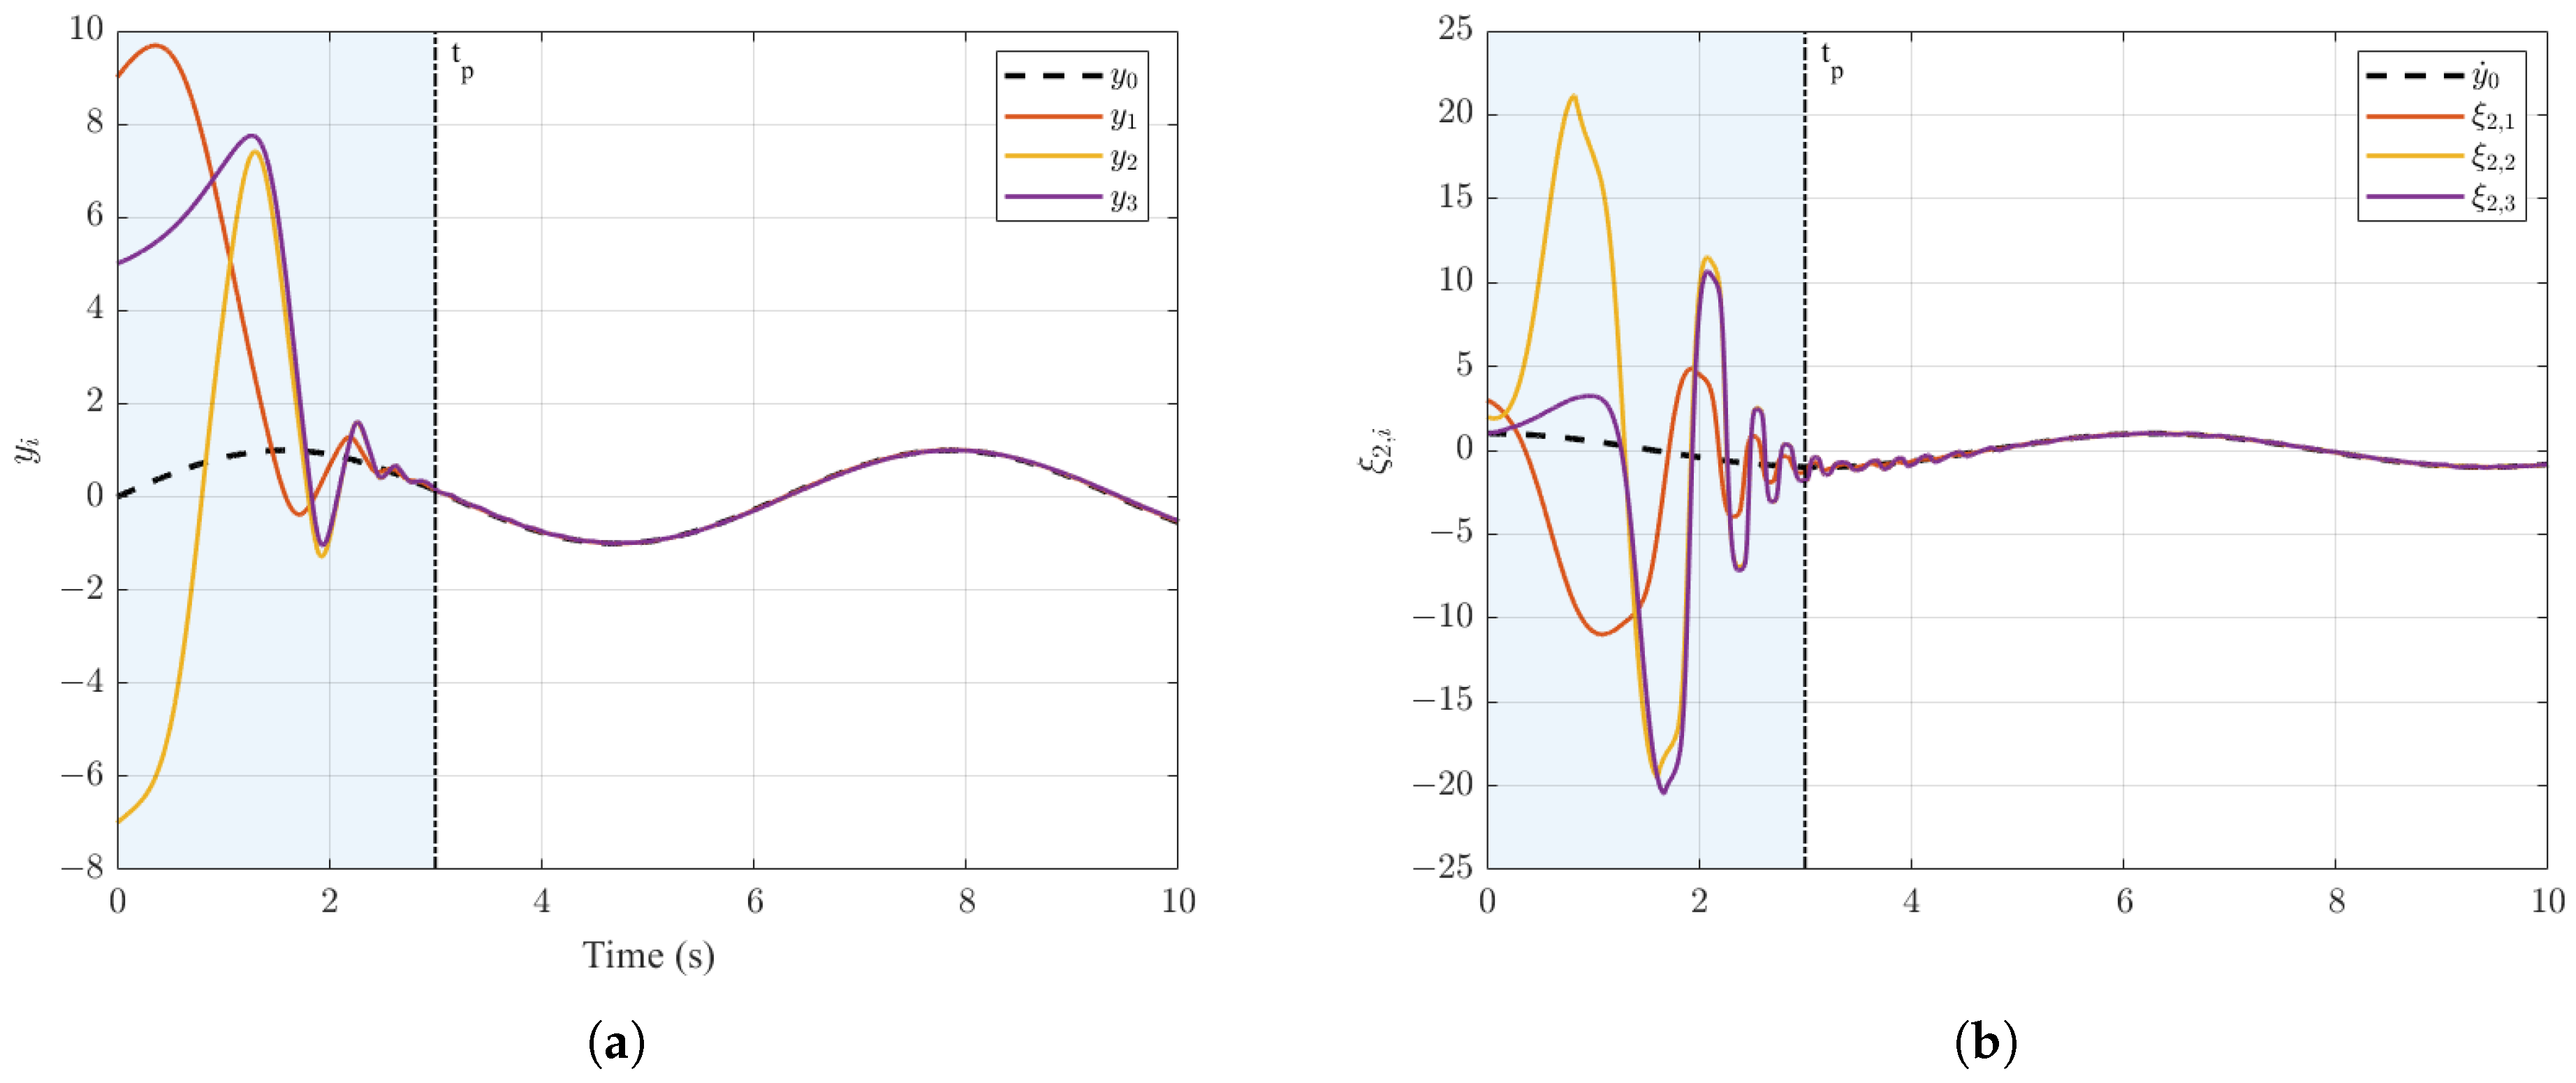
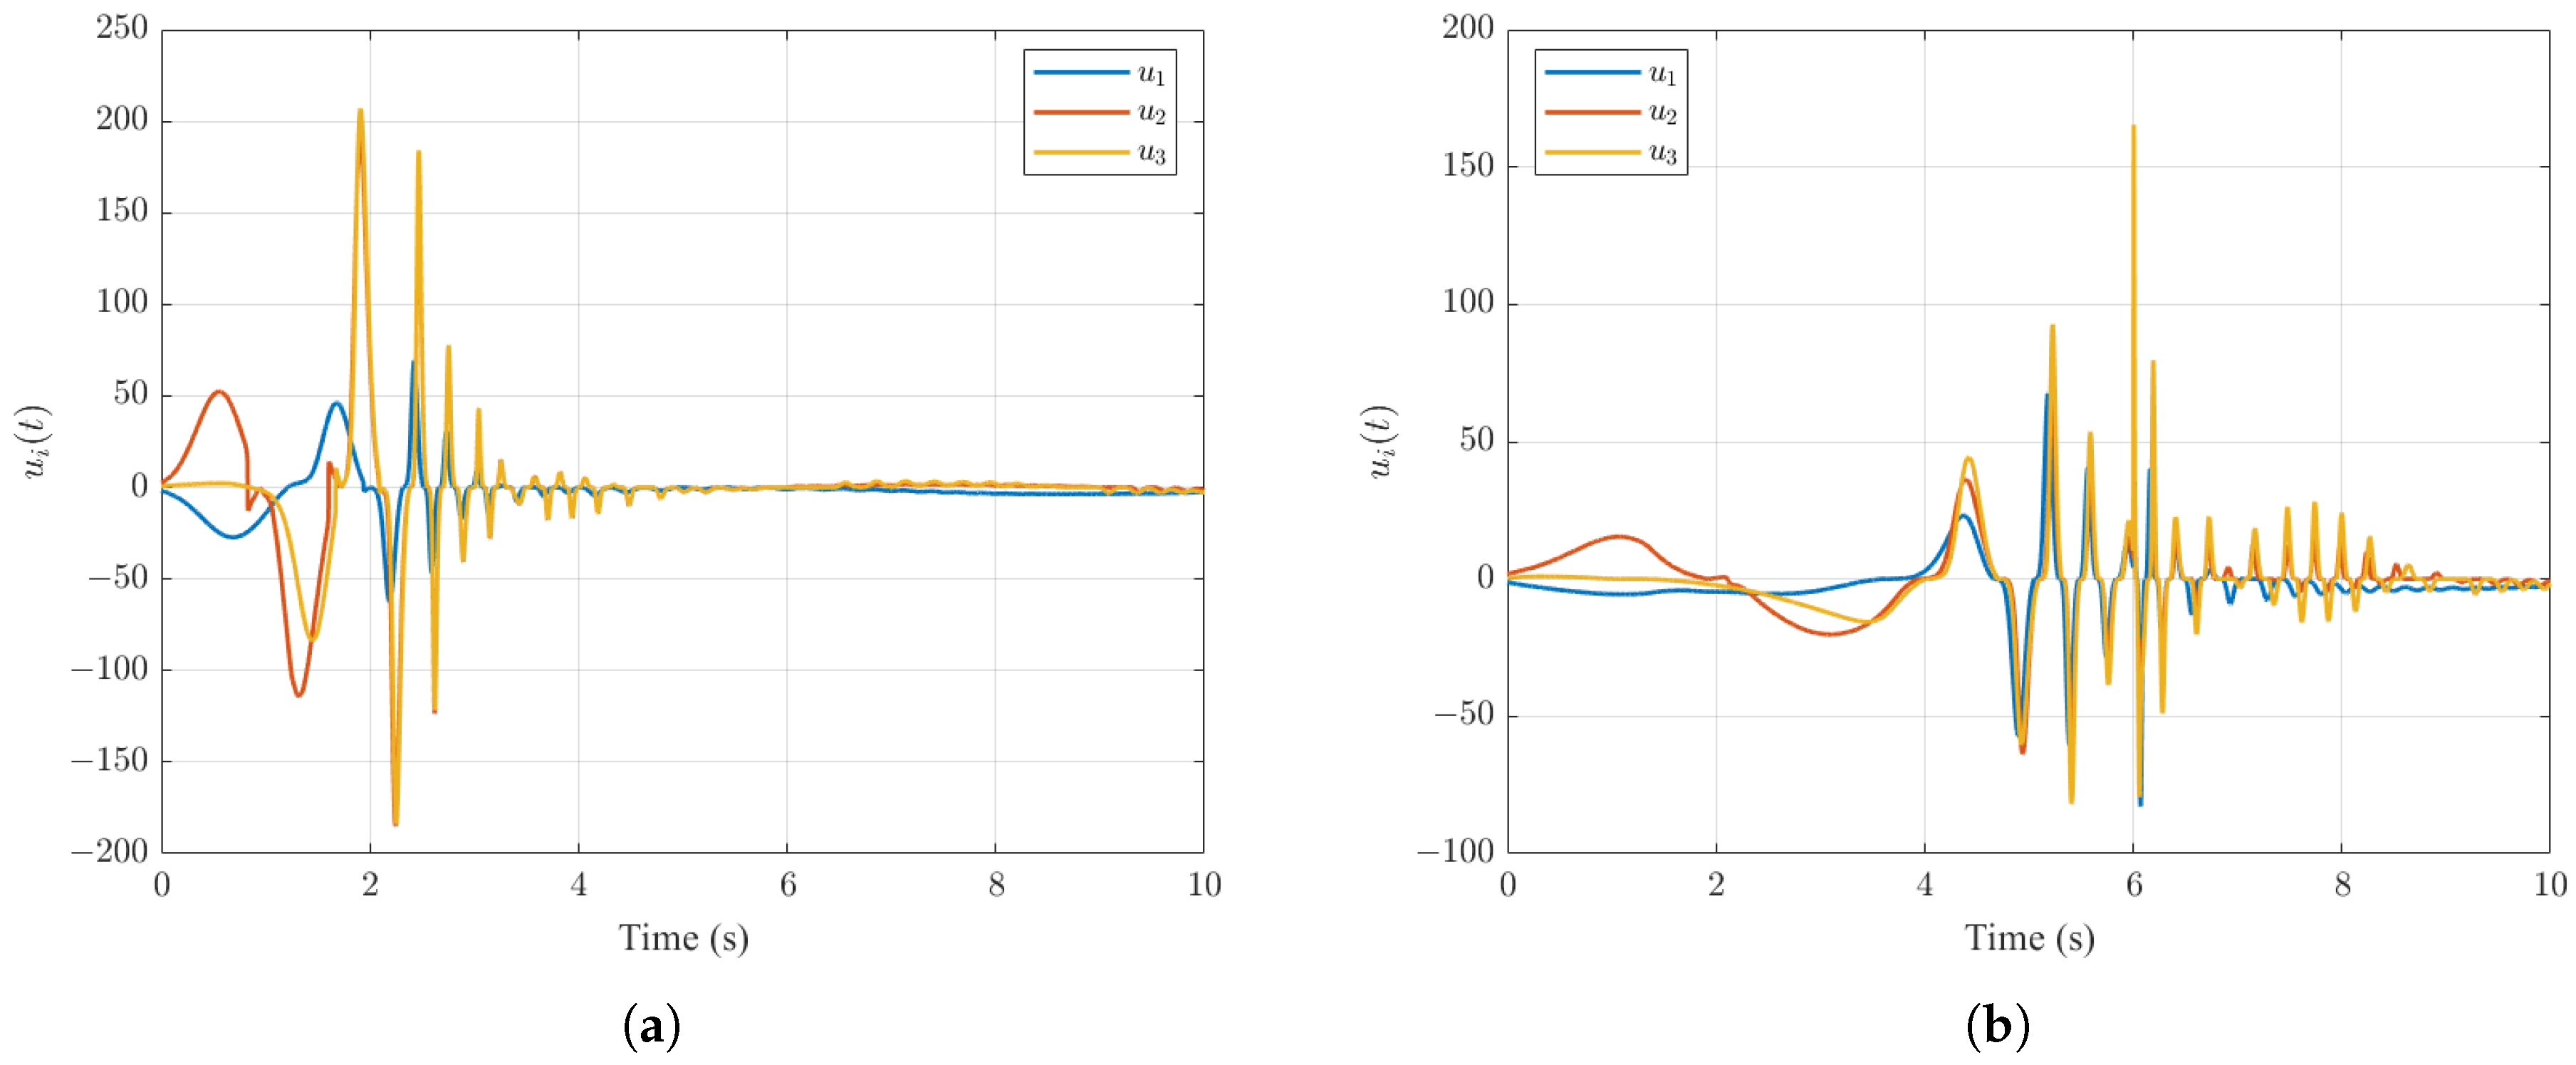
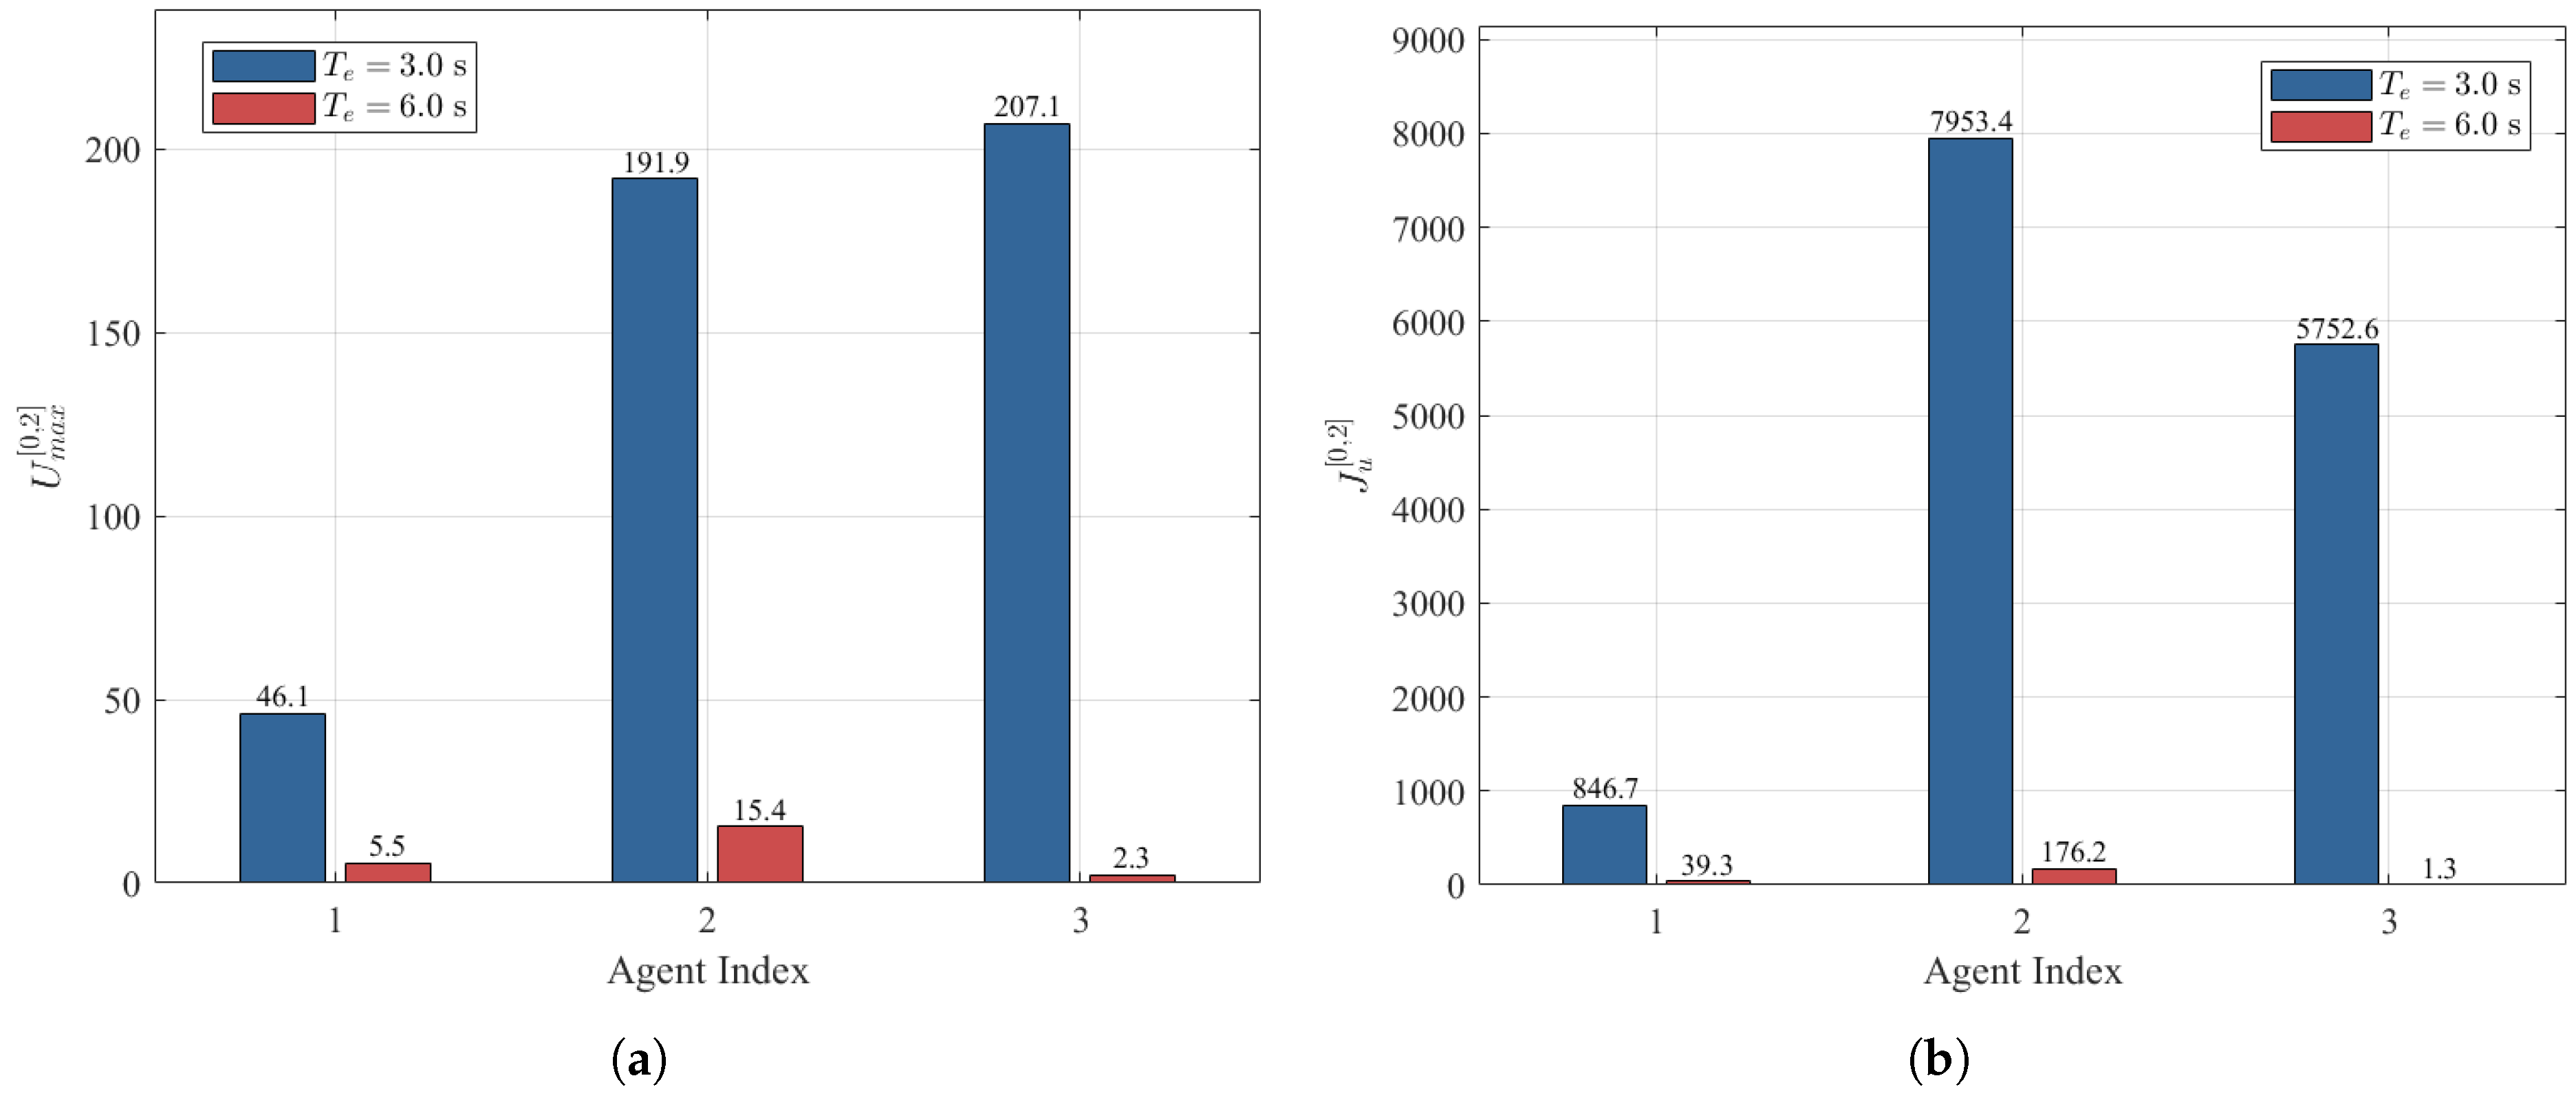
- The closed-loop analysis establishes boundedness of all internal signals and guarantees that the consensus tracking errors reach an adjustable residual region no later than the prescribed time. The effect of the relevant design parameters on the residual estimate is further explained, revealing the practical compromise between tracking precision and control effort.
2. Preliminaries and Problem Formulation
2.1. Preliminaries
- (1)
- ;
- (2)
- is strictly decreasing on , with and ;
- (3)
- The first-order derivative of is given bywhich is monotonically increasing on and satisfies , ;
- (4)
- The second-order derivative of is given bywhich is bounded and nonnegative on .
- (1)
- ;
- (2)
- for all ;
- (3)
- is monotonically nondecreasing on ;
- (4)
- is bounded on and satisfies
- (5)
- is continuous and bounded on and satisfies .
2.2. Graph Theory
2.3. Problem Formulation
- (1)
- Loss of Effectiveness: and .
- (2)
- Bias Fault: and .
- (3)
- Fault-Free: and .
2.4. Auxiliary Lemmas
3. Main Results
3.1. Adaptive PT Control Design
3.2. Stability Analysis
4. Simulations
4.1. Example 1: Heterogeneous Nonlinear Multi-Agent System
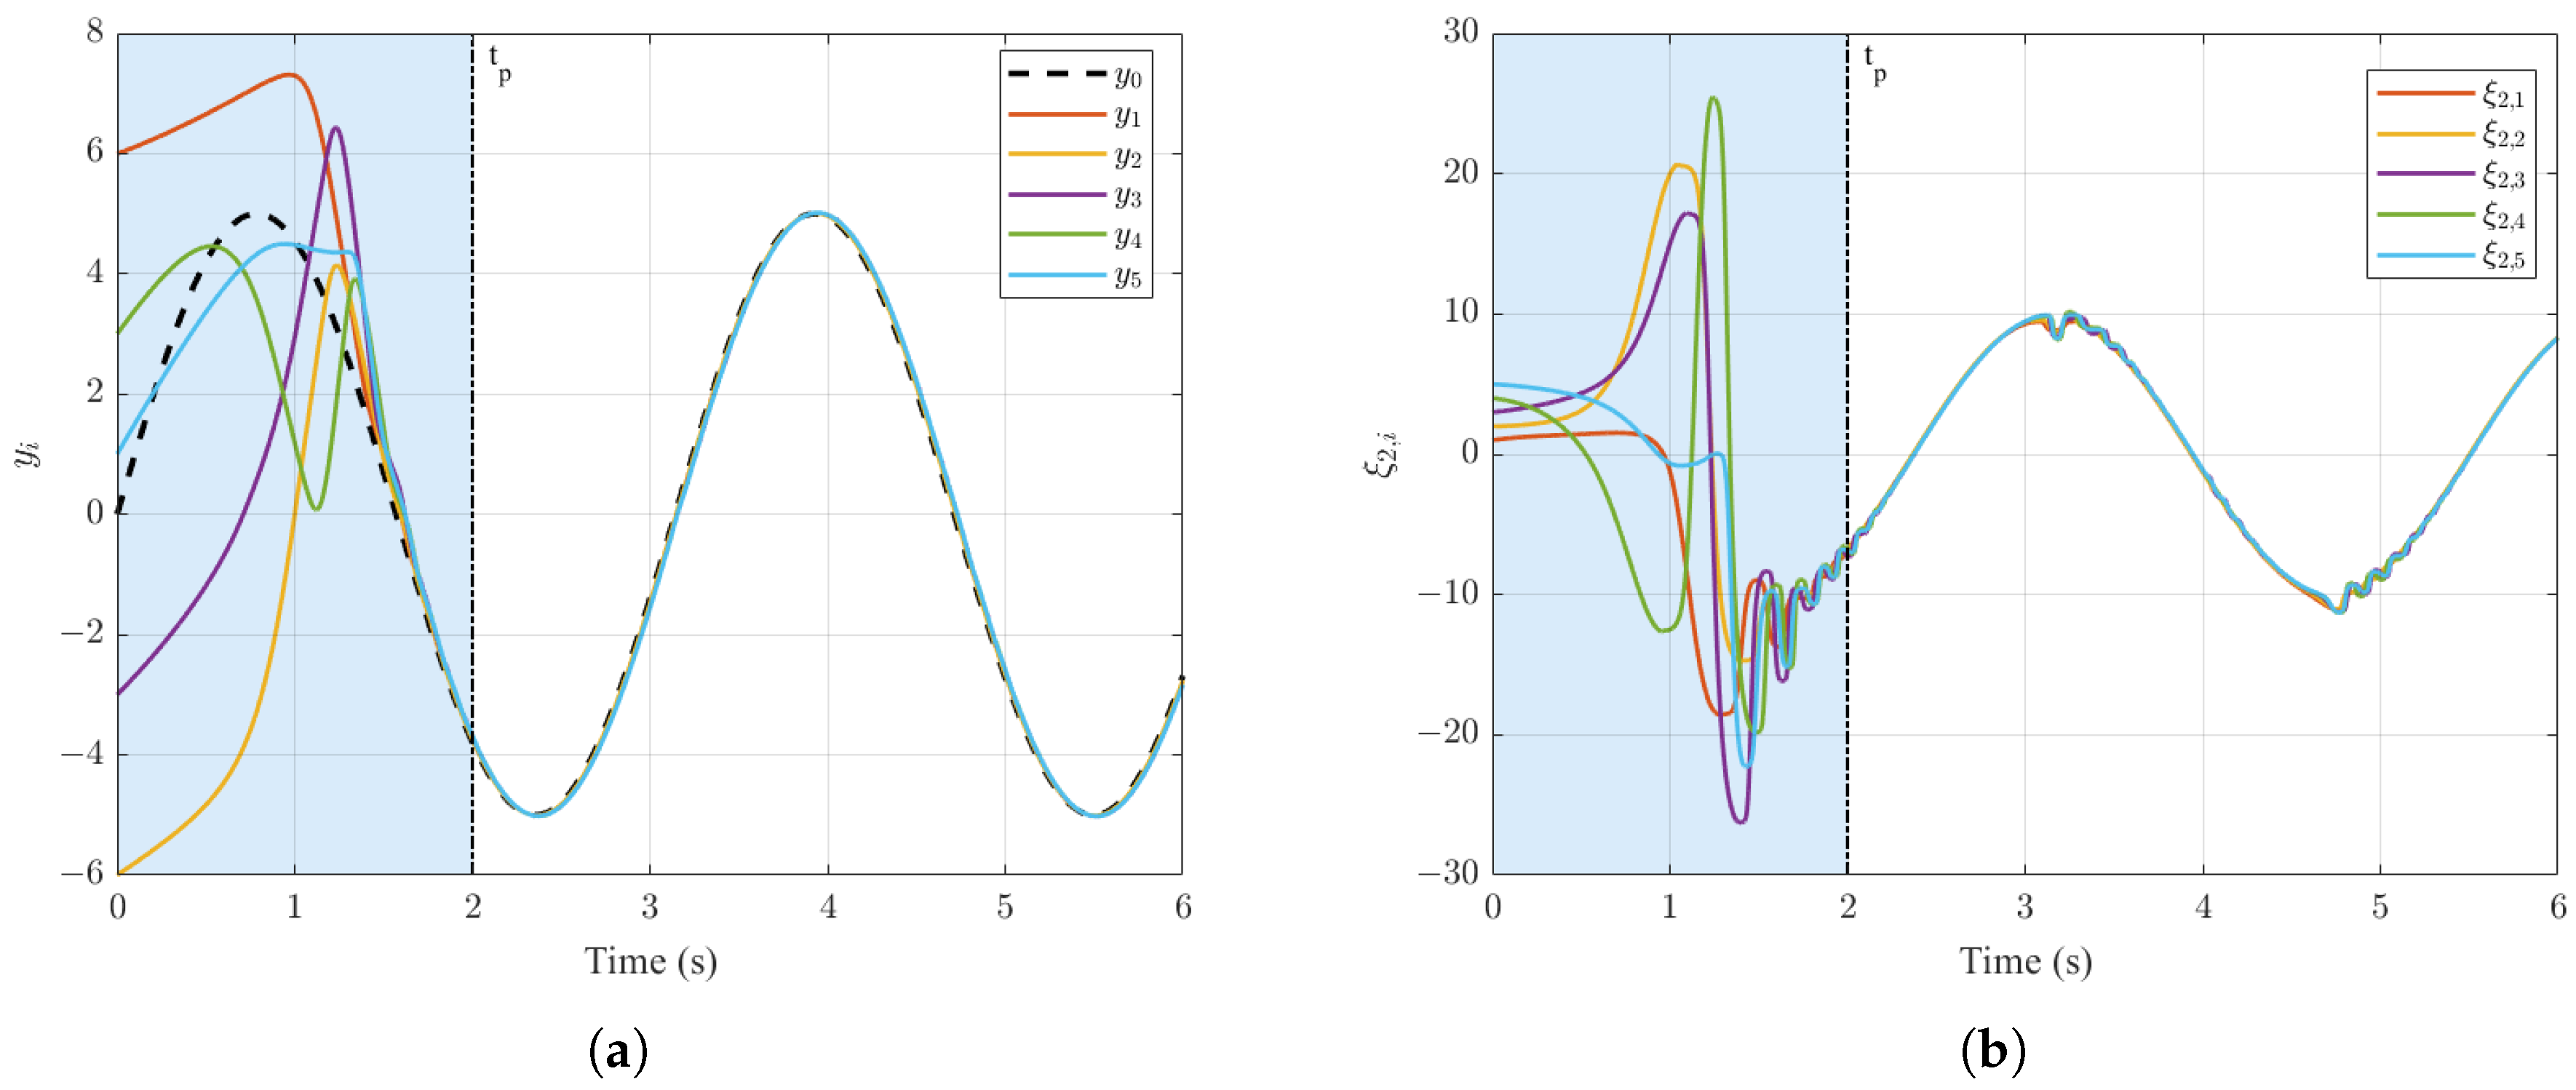
4.2. Example 2: Single-Link Robotic Manipulators
5. Conclusions
Author Contributions
Funding
Data Availability Statement
Conflicts of Interest
References
- Xu, T.; Yi, X.; Wen, G. Distributed fuzzy formation control of multi-UAV systems with directed communication networks. IEEE Trans. Fuzzy Syst. 2025, 33, 3582–3594. [Google Scholar] [CrossRef] [Scilit]
- Yu, Z.; Qu, Y.; Zhang, Y. Distributed fault-tolerant cooperative control for multi-UAVs under actuator fault and input saturation. IEEE Trans. Control Syst. Technol. 2019, 27, 2417–2429. [Google Scholar] [CrossRef] [Scilit]
- Li, X.; Wen, C.; Chen, C.; Xu, Q. Adaptive resilient secondary control for microgrids with communication faults. IEEE Trans. Cybern. 2022, 52, 8493–8503. [Google Scholar] [CrossRef] [Scilit]
- Zhang, W.; Qian, T.; Chen, X.; Huang, K.; Tang, W.; Wu, Q. Resilient economic control for distributed microgrids under false data injection attacks. IEEE Trans. Smart Grid 2021, 12, 4435–4446. [Google Scholar] [CrossRef] [Scilit]
- Ning, B.; Han, Q.-L.; Lu, Q. Fixed-time leader-following consensus for multiple wheeled mobile robots. IEEE Trans. Cybern. 2020, 50, 4381–4392. [Google Scholar] [CrossRef] [Scilit]
- Peng, J.; Zhang, X.; Wang, Y.; Liu, J. Consensus formation control of wheeled mobile robots with mixed disturbances. J. Frankl. Inst. 2024, 361, 106932. [Google Scholar] [CrossRef] [Scilit]
- Luo, D.; Wang, Y.; Lewis, F.L.; Song, Y. Unified output-feedback-based prescribed performance consensus tracking control of heterogeneous multi-agent systems. IEEE/CAA J. Autom. Sin. 2025, 12, 1636–1647. [Google Scholar] [CrossRef] [Scilit]
- Tan, X.; Hu, C.; Cao, G.; Wei, Q.; Li, W.; Han, B. Fixed-time antidisturbance consensus tracking for nonlinear multiagent systems with matching and mismatching disturbances. IEEE/CAA J. Autom. Sin. 2024, 46, 1410–1423. [Google Scholar] [CrossRef] [Scilit]
- Zhang, K.; Zhou, B.; Wen, G. Global leader-following consensus of double-integrator multiagent systems by fully distributed bounded linear protocols. IEEE Trans. Autom. Control 2022, 67, 4846–4853. [Google Scholar] [CrossRef] [Scilit]
- Modares, H.; Kiumarsi, B.; Lewis, F.L.; Ferrese, F.; Davoudi, A. Resilient and robust synchronization of multiagent systems under attacks on sensors and actuators. IEEE Trans. Cybern. 2020, 50, 1240–1250. [Google Scholar] [CrossRef] [Scilit]
- Huang, J.; Dou, L.; Fang, H.; Chen, J. Distributed backstepping-based adaptive fuzzy control of multiple high-order nonlinear dynamics. Nonlinear Dyn. 2015, 8, 63–75. [Google Scholar] [CrossRef] [Scilit]
- Zhao, X.; Chen, S.; Zhang, Z.; Zheng, Y. Consensus tracking for high-order uncertain nonlinear MASs via adaptive backstepping approach. IEEE Trans. Cybern. 2023, 53, 1248–1259. [Google Scholar] [CrossRef] [Scilit]
- Wang, G.; Wang, C.; Li, L. Fully distributed low-complexity control for nonlinear strict-feedback multiagent systems with unknown dead-zone inputs. IEEE Trans. Syst. Man Cybern. Syst. 2020, 50, 421–431. [Google Scholar] [CrossRef] [Scilit]
- Zhao, X.; Chen, S.; Zhang, Z.; Zheng, Y. Observer-based adaptive scaled tracking control for nonlinear MASs via command-filtered backstepping. IEEE Trans. Syst. Man Cybern. Syst. 2023, 53, 425–437. [Google Scholar] [CrossRef] [Scilit]
- Yao, D.; Dou, C.; Yue, D.; Zhao, N.; Zhang, T. Adaptive neural network consensus tracking control for uncertain multi-agent systems with predefined accuracy. Nonlinear Dyn. 2020, 101, 2249–2262. [Google Scholar] [CrossRef] [Scilit]
- Shang, Y.; Chen, B.; Lin, C. Consensus tracking control for distributed nonlinear multiagent systems via adaptive neural backstepping approach. IEEE Trans. Syst. Man Cybern. Syst. 2020, 50, 2436–2444. [Google Scholar] [CrossRef] [Scilit]
- Sun, J.; Liu, C. Distributed fuzzy adaptive backstepping optimal control for nonlinear multimissile guidance systems with input saturation. IEEE Trans. Fuzzy Syst. 2019, 27, 447–461. [Google Scholar]
- Cao, Y.; Ren, W.; Meng, Z. Decentralized finite-time sliding mode estimators and their applications in decentralized finite-time formation tracking. Syst. Control Lett. 2010, 59, 522–529. [Google Scholar] [CrossRef] [Scilit]
- Zhao, Y.; Liu, Y.; Wen, G.; Huang, T. Finite-time distributed average tracking for second-order nonlinear systems. IEEE Trans. Neural Netw. Learn. Syst. 2019, 30, 1780–1789. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Liu, D.; Liu, Z.; Chen, C.L.; Zhang, Y. Finite-time distributed cooperative control for heterogeneous nonlinear multi-agent systems with unknown input constraints. Neurocomputing 2020, 415, 123–134. [Google Scholar] [CrossRef] [Scilit]
- Chen, D.; Liu, X.; Yu, W. Finite-time fuzzy adaptive consensus for heterogeneous nonlinear multi-agent systems. IEEE Trans. Netw. Sci. Eng. 2020, 7, 3057–3066. [Google Scholar] [CrossRef] [Scilit]
- Liu, Y.J.; Shang, X.; Tang, L.; Zhang, S. Finite-time consensus adaptive neural network control for nonlinear multiagent systems under PDE models. IEEE Trans. Neural Netw. Learn. Syst. 2025, 36, 6218–6228. [Google Scholar] [CrossRef] [Scilit]
- Zhang, D.; Chen, H.; Lu, Q.; Feng, G. Finite-time cooperative output regulation of heterogeneous nonlinear multi-agent systems under switching DoS attacks. Automatica 2025, 173, 112062. [Google Scholar] [CrossRef] [Scilit]
- Polyakov, A.; Efimov, D.; Perruquetti, W. Finite-time and fixed-time stabilization: Implicit Lyapunov function approach. Automatica 2015, 51, 332–340. [Google Scholar] [CrossRef] [Scilit]
- Tian, B.; Lu, H.; Zuo, Z.; Yang, W. Fixed-time leader–follower output feedback consensus for second-order multiagent systems. IEEE Trans. Cybern. 2019, 49, 1545–1550. [Google Scholar] [CrossRef] [Scilit]
- Zhang, L.; Chen, B.; Lin, C.; Shang, Y. Fuzzy adaptive fixed-time consensus tracking control of high-order multi-agent systems. IEEE Trans. Fuzzy Syst. 2022, 30, 567–578. [Google Scholar] [CrossRef] [Scilit]
- Cao, L.; Cheng, Z.; Liu, Y.; Li, H. Event-based adaptive NN fixed-time cooperative formation for multiagent systems. IEEE Trans. Neural Netw. Learn. Syst. 2024, 25, 6467–6477. [Google Scholar] [CrossRef] [Scilit]
- Song, Y.; Wang, Y.; Holloway, J.; Krstic, M. Time-varying feedback for regulation of normal-form nonlinear systems in prescribed finite time. Automatica 2017, 83, 243–251. [Google Scholar] [CrossRef] [Scilit]
- Wang, Y.; Song, Y.; Hill, D.J.; Krstic, M. Prescribed-time consensus and containment control of networked multiagent systems. IEEE Trans. Cybern. 2019, 49, 1138–1147. [Google Scholar] [CrossRef] [Scilit]
- Ding, T.F.; Ge, M.F.; Xiong, C.; Liu, Z.-W.; Ling, G. Prescribed-time formation tracking of second-order multi-agent networks with directed graphs. Automatica 2023, 154, 110997. [Google Scholar] [CrossRef] [Scilit]
- Qian, C.; Yu, Z.; Jiang, H.; Luo, Y. Prescribed-time leader-following scaled consensus for high-order nonlinear multi-agent systems. Nonlinear Dyn. 2025, 113, 24751–24770. [Google Scholar] [CrossRef] [Scilit]
- Ning, B.; Han, Q.; Zuo, Z. Practical fixed-time consensus for integrator-type multi-agent systems: A time base generator approach. Automatica 2019, 105, 406–414. [Google Scholar] [CrossRef] [Scilit]
- Zou, A.; Liu, Y.; Hou, Z.; Hu, Z. Practical predefined-time output-feedback consensus tracking control for multiagent systems. IEEE Trans. Cybern. 2023, 53, 5311–5322. [Google Scholar] [CrossRef] [Scilit]
- Luo, D.; Wang, Y.; Song, Y. Practical prescribed time tracking control with bounded time-varying gain under non-vanishing uncertainties. IEEE/CAA J. Autom. Sin. 2024, 11, 219–230. [Google Scholar] [CrossRef] [Scilit]
- Gallehdari, Z.; Meskin, N.; Khorasani, K. A distributed control reconfiguration and accommodation for consensus achievement of multiagent systems subject to actuator faults. IEEE Trans. Control Syst. Technol. 2016, 24, 2031–2047. [Google Scholar] [CrossRef] [Scilit]
- Khalili, M.; Zhang, X.; Polycarpou, M.; Polycarpou, T.; Cao, Y. Distributed adaptive fault-tolerant control of uncertain multi-agent systems. Automatica 2018, 87, 142–151. [Google Scholar] [CrossRef] [Scilit]
- Deng, C.; Yang, G. Distributed adaptive fault-tolerant control approach to cooperative output regulation for linear multi-agent systems. Automatica 2019, 103, 62–68. [Google Scholar] [CrossRef] [Scilit]
- Wu, W.; Tong, S. Fuzzy adaptive consensus control for nonlinear multiagent systems with intermittent actuator faults. IEEE Trans. Cybern. 2023, 53, 2969–2979. [Google Scholar] [CrossRef] [Scilit]
- Rotondo, D.; Theilliol, D.; Ponsart, J.-C. Virtual actuator and sensor fault tolerant consensus for homogeneous linear multi-agent systems. IEEE Trans. Circuits Syst. I Regul. Pap. 2024, 71, 1324–1334. [Google Scholar] [CrossRef] [Scilit]
- Dong, G.; Li, H.; Ma, H.; Lu, R. Finite-time consensus tracking neural network FTC of multi-agent systems. IEEE Trans. Neural Netw. Learn. Syst. 2021, 32, 653–662. [Google Scholar] [CrossRef] [Scilit]
- Zhang, P.; Xue, H.; Gao, S.; Zuo, X.; Zhang, J. Finite-time adaptive cooperative fault-tolerant control for multi-agent system with hybrid actuator faults. IEEE Syst. J. 2022, 16, 3590–3601. [Google Scholar] [CrossRef] [Scilit]
- Ren, H.; Ma, H.; Li, H.; Wang, Z. Adaptive fixed-time control of nonlinear MASs with actuator faults. IEEE/CAA J. Autom. Sin. 2023, 8, 1252–1262. [Google Scholar] [CrossRef] [Scilit]
- Lu, L.T.; Zhu, S.L.; Wang, D.M.; Han, Y.Q. Predefined-time adaptive consensus control for nonlinear multi-agent systems with input quantization and actuator faults. Nonlinear Dyn. 2024, 112, 14215–14234. [Google Scholar] [CrossRef] [Scilit]
- Zou, Z.; Wang, C. Adaptive trajectory tracking control of output constrained multi-rotors systems. IET Control Theory Appl. 2014, 8, 1163–1174. [Google Scholar]







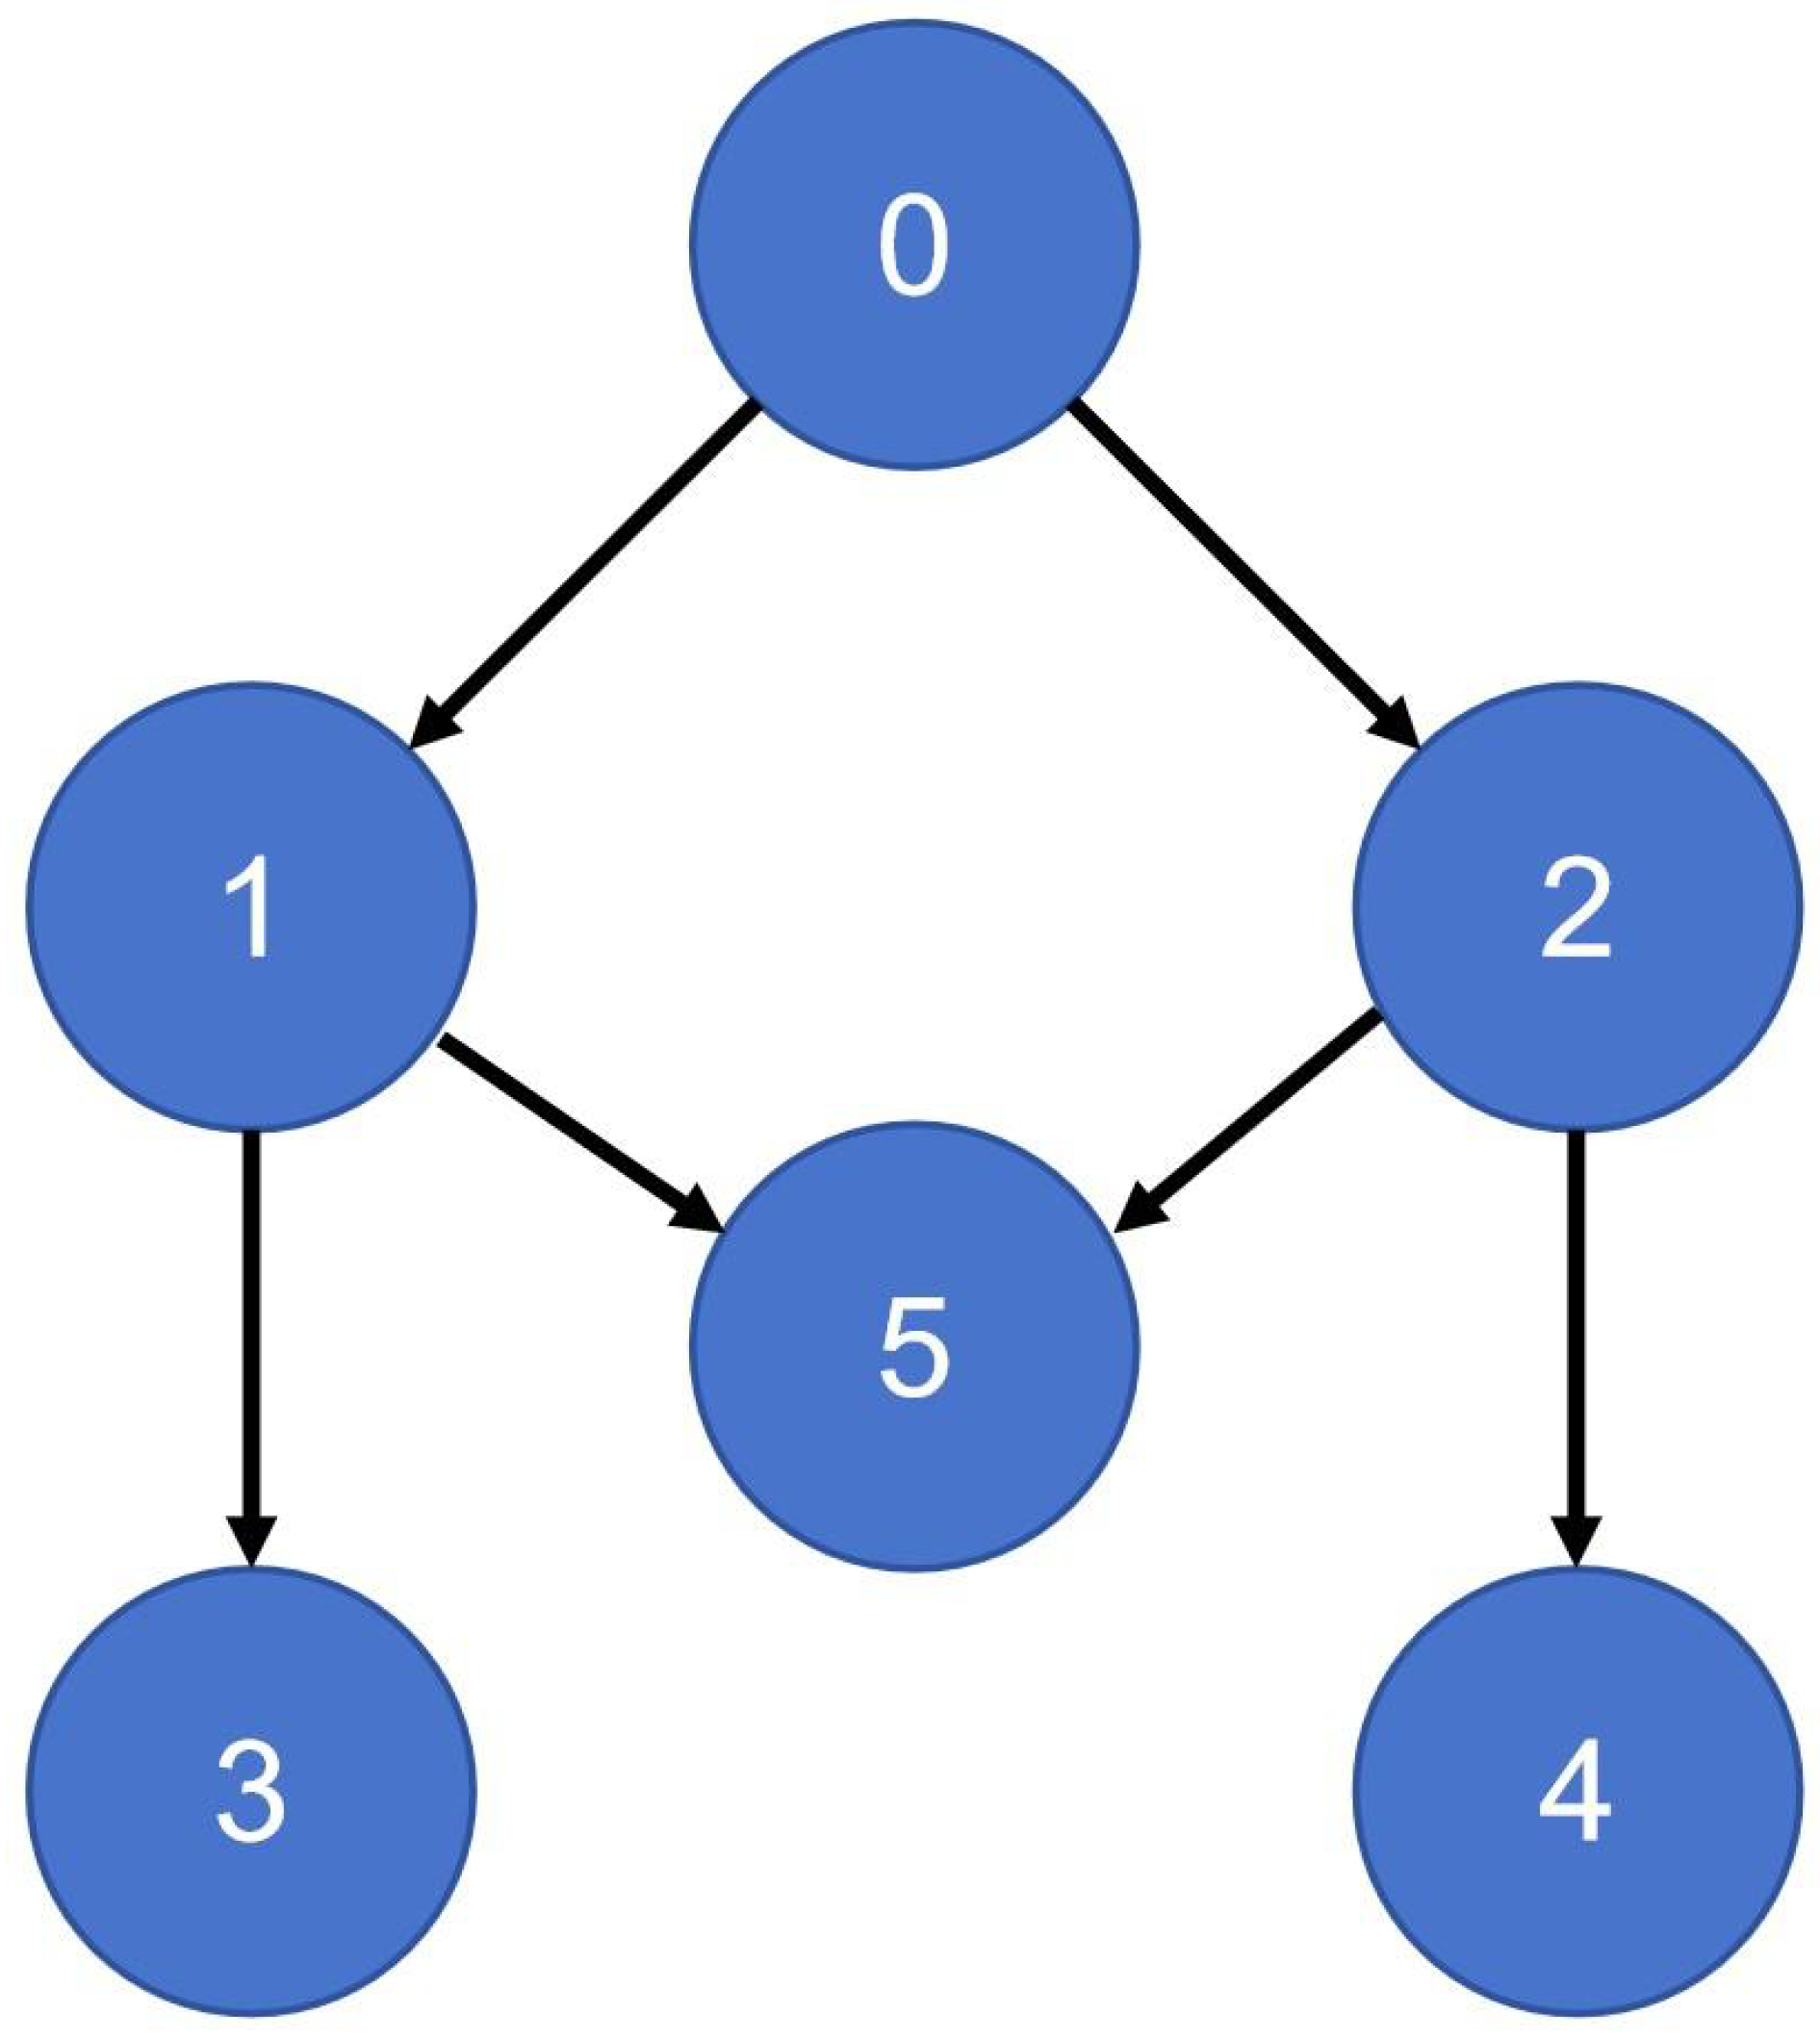
| Follower | ||
|---|---|---|
| 1 | ||
| 2 | 1 | 0 |
| 3 | 0 | |
| 4 | 1 | 0 |
| 5 | 1 | 0 |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Zhao, L.; Chen, S.; Jin, H. Adaptive Prescribed-Time Bounded Consensus Tracking for Nonlinear Multi-Agent Systems with Actuator Faults. Mathematics 2026, 14, 1919. https://doi.org/10.3390/math14111919
Zhao L, Chen S, Jin H. Adaptive Prescribed-Time Bounded Consensus Tracking for Nonlinear Multi-Agent Systems with Actuator Faults. Mathematics. 2026; 14(11):1919. https://doi.org/10.3390/math14111919
Chicago/Turabian StyleZhao, Lei, Shiming Chen, and Huanghuang Jin. 2026. "Adaptive Prescribed-Time Bounded Consensus Tracking for Nonlinear Multi-Agent Systems with Actuator Faults" Mathematics 14, no. 11: 1919. https://doi.org/10.3390/math14111919
APA StyleZhao, L., Chen, S., & Jin, H. (2026). Adaptive Prescribed-Time Bounded Consensus Tracking for Nonlinear Multi-Agent Systems with Actuator Faults. Mathematics, 14(11), 1919. https://doi.org/10.3390/math14111919