


Abstract
Research on surfaces generated by curves plays a central role in linking differential geometry with physical applications, especially following Hasimoto’s transformation and the development of Hasimoto-inspired surface models. In this work, we introduce a new class of such surfaces, referred to as RM Hasimoto surfaces, constructed by employing the rotation-minimizing (RM) Darboux frame along both timelike and spacelike curves in Minkowski 3-space . In contrast to the classical Hasimoto surfaces defined via the Frenet or standard Darboux frames, the RM approach eliminates torsional difficulties and reduces redundant rotational effects. This leads to more straightforward expressions for the first and second fundamental forms, as well as for the Gaussian and mean curvatures, and facilitates a clear classification of key parameter curves. Furthermore, we establish the associated evolution equations, analyze the resulting geometric invariants, and present explicit examples based on timelike and spacelike generating curves. The findings show that adopting the RM Darboux frame provides greater transparency in Lorentzian surface geometry, yielding sharper characterizations and offering new perspectives on relativistic vortex filaments, magnetic field structures, and soliton behavior. Thus, the RM framework opens a promising direction for both theoretical studies and practical applications of surface geometry in Minkowski space.
MSC:
53A05; 53A5; 70B99; 37K25
1. Introduction
The study of surfaces generated by curves provides a fundamental connection between differential geometry and the modeling of filamentary structures in physics. A central theme in this area is the interplay between vortex filament dynamics and integrable systems. The motion of vortex filaments is governed by the vortex filament equation (VFE), also known as the localized induction approximation (LIA), which prescribes the evolution of a space curve in terms of its curvature and torsion . In Euclidean three-space, this evolution is expressed as
A major breakthrough was achieved by Hasimoto, who introduced a transformation that encodes the curve’s curvature and torsion into a single complex function. Specifically, by setting
he proved that satisfies the cubic nonlinear Schrödinger equation (NLS):
This correspondence established a direct link between vortex filament motion and soliton theory, revealing that filament dynamics exhibit soliton-like behavior [3].
The significance of Hasimoto’s transformation extends well beyond fluid dynamics, connecting diverse physical systems governed by similar nonlinear structures. In plasma physics, the dynamics of vortex filaments under the localized induction approximation naturally correspond to solutions of the NLS equation, enabling soliton-based interpretations of magnetic flux tubes and filament stability. This correspondence also manifests in superconductivity, where quantized vortex lines within superconducting materials follow analogous geometric evolutions, and Hasimoto surfaces provide an effective geometric framework for exploring vortex antivortex interactions and quantum turbulence [4]. A comparable unifying picture emerges in nonlinear optics, where the propagation of light in fibers and waveguides is likewise modeled by the NLS equation. Here, representing optical beam trajectories through Hasimoto-type surfaces offers geometric insight into how curvature and torsion influence soliton formation and pulse stability. Together, these examples underscore a central theme: the geometry of Hasimoto surfaces serves as a universal language for describing the interplay between curvature driven dynamics and soliton phenomena across multiple areas of modern physics.
Applications extend further to nonlinear optics. In optical fibers and waveguides, light propagation is modeled by the NLS equation, with soliton solutions capturing the stability of localized pulses. In optical fibers and waveguides, light propagation is governed by the nonlinear Schrödinger equation, where soliton solutions describe the stable transmission of localized pulses. Modeling these systems through Hasimoto-type surfaces provides geometric insight into how curvature and torsion affect soliton formation and beam evolution.
Traditionally, these surfaces are constructed using the Frenet or classical Darboux frame of the generating curve, leading to a detailed classification of curvature properties, fundamental forms, and characteristic curves [5,6,7,8]. More recently, Hasimoto-type surfaces have been generalized to Lorentzian geometry, where the behavior depends strongly on whether the generating curve is timelike or spacelike [9,10,11]. Parallel developments have introduced the rotation-minimizing (RM) Darboux frame into Minkowski space, producing new results on ruled and tubular surfaces [12,13,14,15,16,17]. The RM Darboux frame is particularly advantageous, as it avoids torsional terms, remains valid for all non-lightlike curves, and minimizes unnecessary rotation of the normal plane. In Minkowski 3-space , this leads to streamlined formulas for the fundamental forms, Gaussian and mean curvatures, and clearer classifications of geodesics, asymptotic curves, and principal directions.
From a geometric perspective, Hasimoto surfaces provide powerful tools for visualizing and analyzing vortex filament flows. Yet, the choice of moving frame along the generating curve significantly influences both the complexity and the interpretability of the resulting surface geometry. Frenet and Darboux frames involve torsion, which can obscure the geometric structure by introducing additional rotational effects.
In this paper, we advance the subject by formulating RM Hasimoto surfaces using the RM Darboux frame along timelike and spacelike curves in Minkowski . We derive explicit expressions for the fundamental forms, compute Gaussian and mean curvatures, and classify the associated special parameter curves. In addition, we establish the evolution laws of RM Hasimoto surfaces under the binormal (localized induction) flow and explore the corresponding conservation properties. Our contributions can be summarized as follows: (i) the formulation of RM Hasimoto surfaces for timelike and spacelike base curves; (ii) simplified curvature invariants and classification of principal surface curves; (iii) derivation of evolution equations and associated conservation laws; (iv) worked examples illustrating the advantages of the RM formulation compared with Frenet-based constructions. The remainder of this paper is organized as follows: Section 2 reviews Minkowski 3-space, the causal character of curves, and the RM Darboux frame. Section 3 introduces the RM Hasimoto surfaces and their fundamental forms and develops the curvature formulas and the classification of special curves. Section 4 evaluates the RM Hasimoto surfaces via RM Darboux frame of their generating curves. Finally, an example and related simulations are presented.
2. Geometric Preliminaries of Curves and Surfaces in Minkowski 3-Space
The Minkowski 3-space, denoted by , is the vector space endowed with the Lorentzian metric of signature , defined by
for and in . A vector is timelike if it represents motion slower than light (), spacelike if it represents spatial directions or faster-than-light separation (), and lightlike (null) if it corresponds to motion at the speed of light (). This causal distinction underlies much of the curve and surface theory in Lorentzian geometry [18,19].
Let be a regular curve parametrized by arc length s. Its tangent vector is
When the curve is non-null (), curvature and torsion are defined analogously to the Euclidean case. The Frenet–Serret frame then satisfies
where and are the curvature and torsion, respectively, and . These equations adapt differently to timelike and spacelike cases [19,20,21].
For a regular surface given locally by , the tangent vectors define the induced metric with coefficients
Christoffel symbols of the second kind are defined as follows (for further details see [19,21]):
If a curve lies on M, the associated Darboux frame is
where g is tangent to M and orthogonal to T. The frame derivatives satisfy
where , , and denote the geodesic curvature, normal curvature, and geodesic torsion, respectively [12,21].
The RM Darboux frame is obtained from via a Lorentz boost with rapidity :
Invert these relations to express in the basis:
Substituting into yields
where and are the natural curvatures relative to the RM frame.
To enforce the RM condition (no rotation of the -plane around T), compute :
The RM condition requires the V-component to vanish, giving
With this choice, the RM Darboux frame equations become [17]:
The second fundamental form of M is
From these, the Gaussian curvature K and mean curvature H follow as
These invariants govern both the intrinsic and extrinsic geometry of surfaces in Minkowski space, and are central to the study of minimal, maximal, and constant mean curvature surfaces [20,21].
3. RM Hasimoto Surfaces in Minkowski 3-Space
In the context of surfaces generated by curves in Minkowski 3-space , Hasimoto-type constructions provide a natural bridge between curve geometry and nonlinear evolution equations. Classical Hasimoto surfaces are formulated with respect to the Frenet frame of a space curve, capturing the evolution of vortex filaments. In what follows, we extend this construction by employing the rotation-minimizing (RM) Darboux frame, which leads to a broader family of surfaces that we refer to as RM Hasimoto surfaces.
Let be a unit-speed regular curve on a surface , and let denote its RM Darboux frame, where T is the tangent vector and form an orthonormal system of rotation-minimizing normals. We define the associated RM Hasimoto surface by
where are smooth profile functions depending on .
Special cases include the following:
- , : a ruled surface in the U-direction;
- , : a ruled surface in the V-direction.
In the general situation, the choice of determines the surface evolution. A particularly convenient parametrization is given in terms of hyperbolic coordinates:
where is a radius function and is a constant. This form reflects the hyperbolic structure of the RM frame when and .
Theorem 1.
Let be a non-null curve in with RM Darboux frame and RM curvatures . Then, the map
defines a regular RM Hasimoto surface whenever and the triple does not vanish simultaneously.
Proof.
Consider the parametrization
where is the RM Darboux frame of and are its RM curvatures. Using Equation (6) and differentiating we have
Introduce
together with
Then
The parametrization is regular if and only if
i.e., and are linearly independent.
Suppose to the contrary that for some . Taking the inner product with T gives . Thus,
This implies that is proportional to , i.e., for some . Expanding in the basis,
This system forces , which would require . Since this is impossible for real t, the vectors and are independent. Thus, linear dependence can occur only if and simultaneously, or if . Both cases contradict the assumptions and . Therefore, , and defines a regular RM Hasimoto surface. □
Now we compute the derivatives:
From these, the coefficients of the first fundamental form are obtained as
The unit normal vector field of the surface can be written as
where we use the shorthand
Theorem 2.
Remarks
- The hyperbolic functions and arise naturally due to the Lorentzian structure of the RM Darboux frame when U and V generate a subspace of mixed signature.
- Special cases include or , which correspond to cylindrical or tubular RM Hasimoto surfaces.
- If the generating curve is a helix in , the surface provides a Lorentzian analog of a Hasimoto vortex surface.
- For orthogonal coordinates (), the Christoffel symbols reduce to
Theorem 3.
Corollary 1.
Proof.
For an s-curve with velocity vector , the geodesic equations reduce to
so . Since , we have , hence gives . On the other hand, with , so yields . □
Corollary 2.
For as above, the t-coordinate curves are geodesics exactly when
Proof.
For the t-curves, the geodesic equations read
Since depends only on s, we obtain , and . Thus, gives . Excluding the trivial case , this condition reduces to . □
Corollary 3.
For , the s-curves are asymptotic precisely when
Proof.
The normal curvature in the s-direction is . Since , asymptoticity is equivalent to . Using (13) gives the stated condition. □
Corollary 4.
For , the t-curves are asymptotic if and only if
Proof.
The normal curvature in the t-direction is . Thus, t-curves are asymptotic when . Substituting from (13) leads to the stated equation. □
Corollary 5.
For , both s- and t-coordinate curves are principal directions exactly when
Proof.
For orthogonal coordinates (), the condition for the coordinate directions to be principal is . From (13), gives the displayed relation. □
4. Evolution of RM Hasimoto Surfaces via the RM Darboux Frame of Their Generating Curves
In this section, we analyze three distinct families of RM Hasimoto surfaces that arise from the vectors of the RM Darboux frame of a spacelike RM curve. Our goal is to examine their differential geometric characteristics and evolutionary behavior. To achieve this, we present the following results.
Theorem 4.
Let be the RM Hasimoto surface generated by the RM tangent vector of a spacelike RM curve whose RM binormal is timelike. Then, the surface is hyperbolic everywhere, i.e., locally saddle-shaped.
Proof.
for certain scalars . We adopt the causal convention
Differentiating (15) gives
Thus, the coefficients of the first fundamental form are
The unnormalized normal vector reads
which is parallel to T. Up to orientation, we may thus take as the unit normal. Differentiation and projection on yield
Consequently, the Gaussian and mean curvatures are
Thus, has a constant negative Gaussian curvature, making it hyperbolic everywhere, while its mean curvature depends on the invariants of the generating curve. □
The RM tangent-based RM Hasimoto surface is given by
where is the RM Darboux frame in Minkowski 3-space, satisfying the structural relations
with , , and c as the RM torsion-like scalar. Time evolutions are described by
Theorem 5.
Let be the RM Hasimoto surface generated by the RM normal vector of a spacelike RM curve whose RM binormal is timelike. Then is pseudospherical, having constant negative Gaussian curvature, and is minimal at all regular points.
Proof.
The RM normal-based Hasimoto surface is
Differentiating (21) gives
With the orthogonality and causal convention, the first fundamental form is
The normal vector becomes
Since , we obtain
so (regularity requires ). Further differentiations lead to
Projecting onto gives
From (23) and (24),
and
Therefore, at regular points (), the curvatures are
Thus, is a pseudospherical minimal surface, with constant Gaussian curvature and vanishing mean curvature. □
Theorem 6.
Let denote the RM Hasimoto surface determined by the RM binormal vector of a spacelike RM curve whose binormal is timelike. Then is of spherical type, possessing constant positive Gaussian curvature.
Proof.
The construction is based on
Differentiating gives
Using the orthogonality of the RM Darboux frame together with the causal convention, the coefficients of the first fundamental form are
The corresponding normal vector is
Since , it follows that
Thus, whenever , the unit normal can be chosen as .
Next, differentiating (27) once more and projecting onto the chosen normal gives
Thus, the coefficients of the second fundamental form are
Comparing (28) and (29), one observes
and
Thus, the numerator and denominator of the curvature expressions coincide. Consequently, at regular points (), the curvatures of are
and if the opposite orientation is selected, the mean curvature changes the sign to while K remains unchanged. Therefore, the RM binormal Hasimoto surface is spherical type, characterized by constant positive Gaussian curvature and mean curvature depending on orientation. □
Example 1.
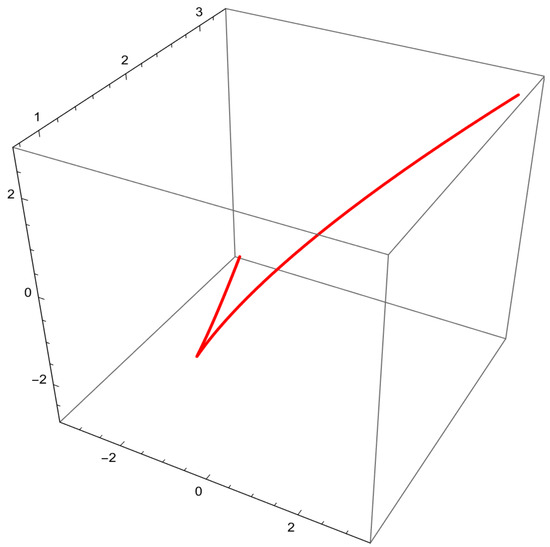
Let us consider the spacelike curve (see Figure 1)
Figure 1.
The spacelike curve , .
The associated Frenet frame vectors together with the curvature κ and the torsion τ along are computed as
Thus, the RM Darboux curvatures follow as
Accordingly, the RM and coordinate components are
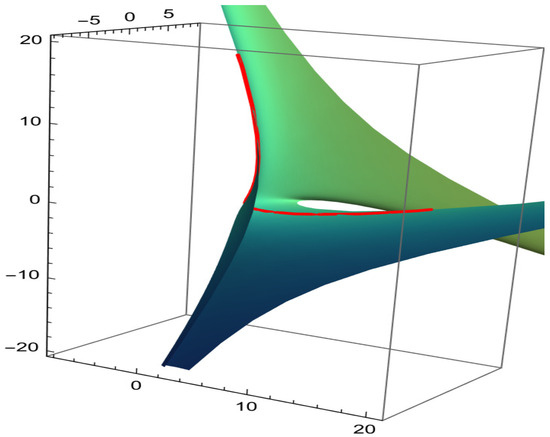
Choosing and , the Hasimoto surface generated by the Frenet frame can be parameterized as
After substituting the explicit expressions, this becomes (see Figure 2)
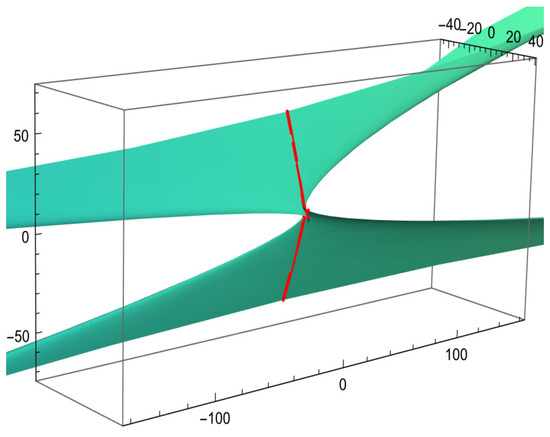
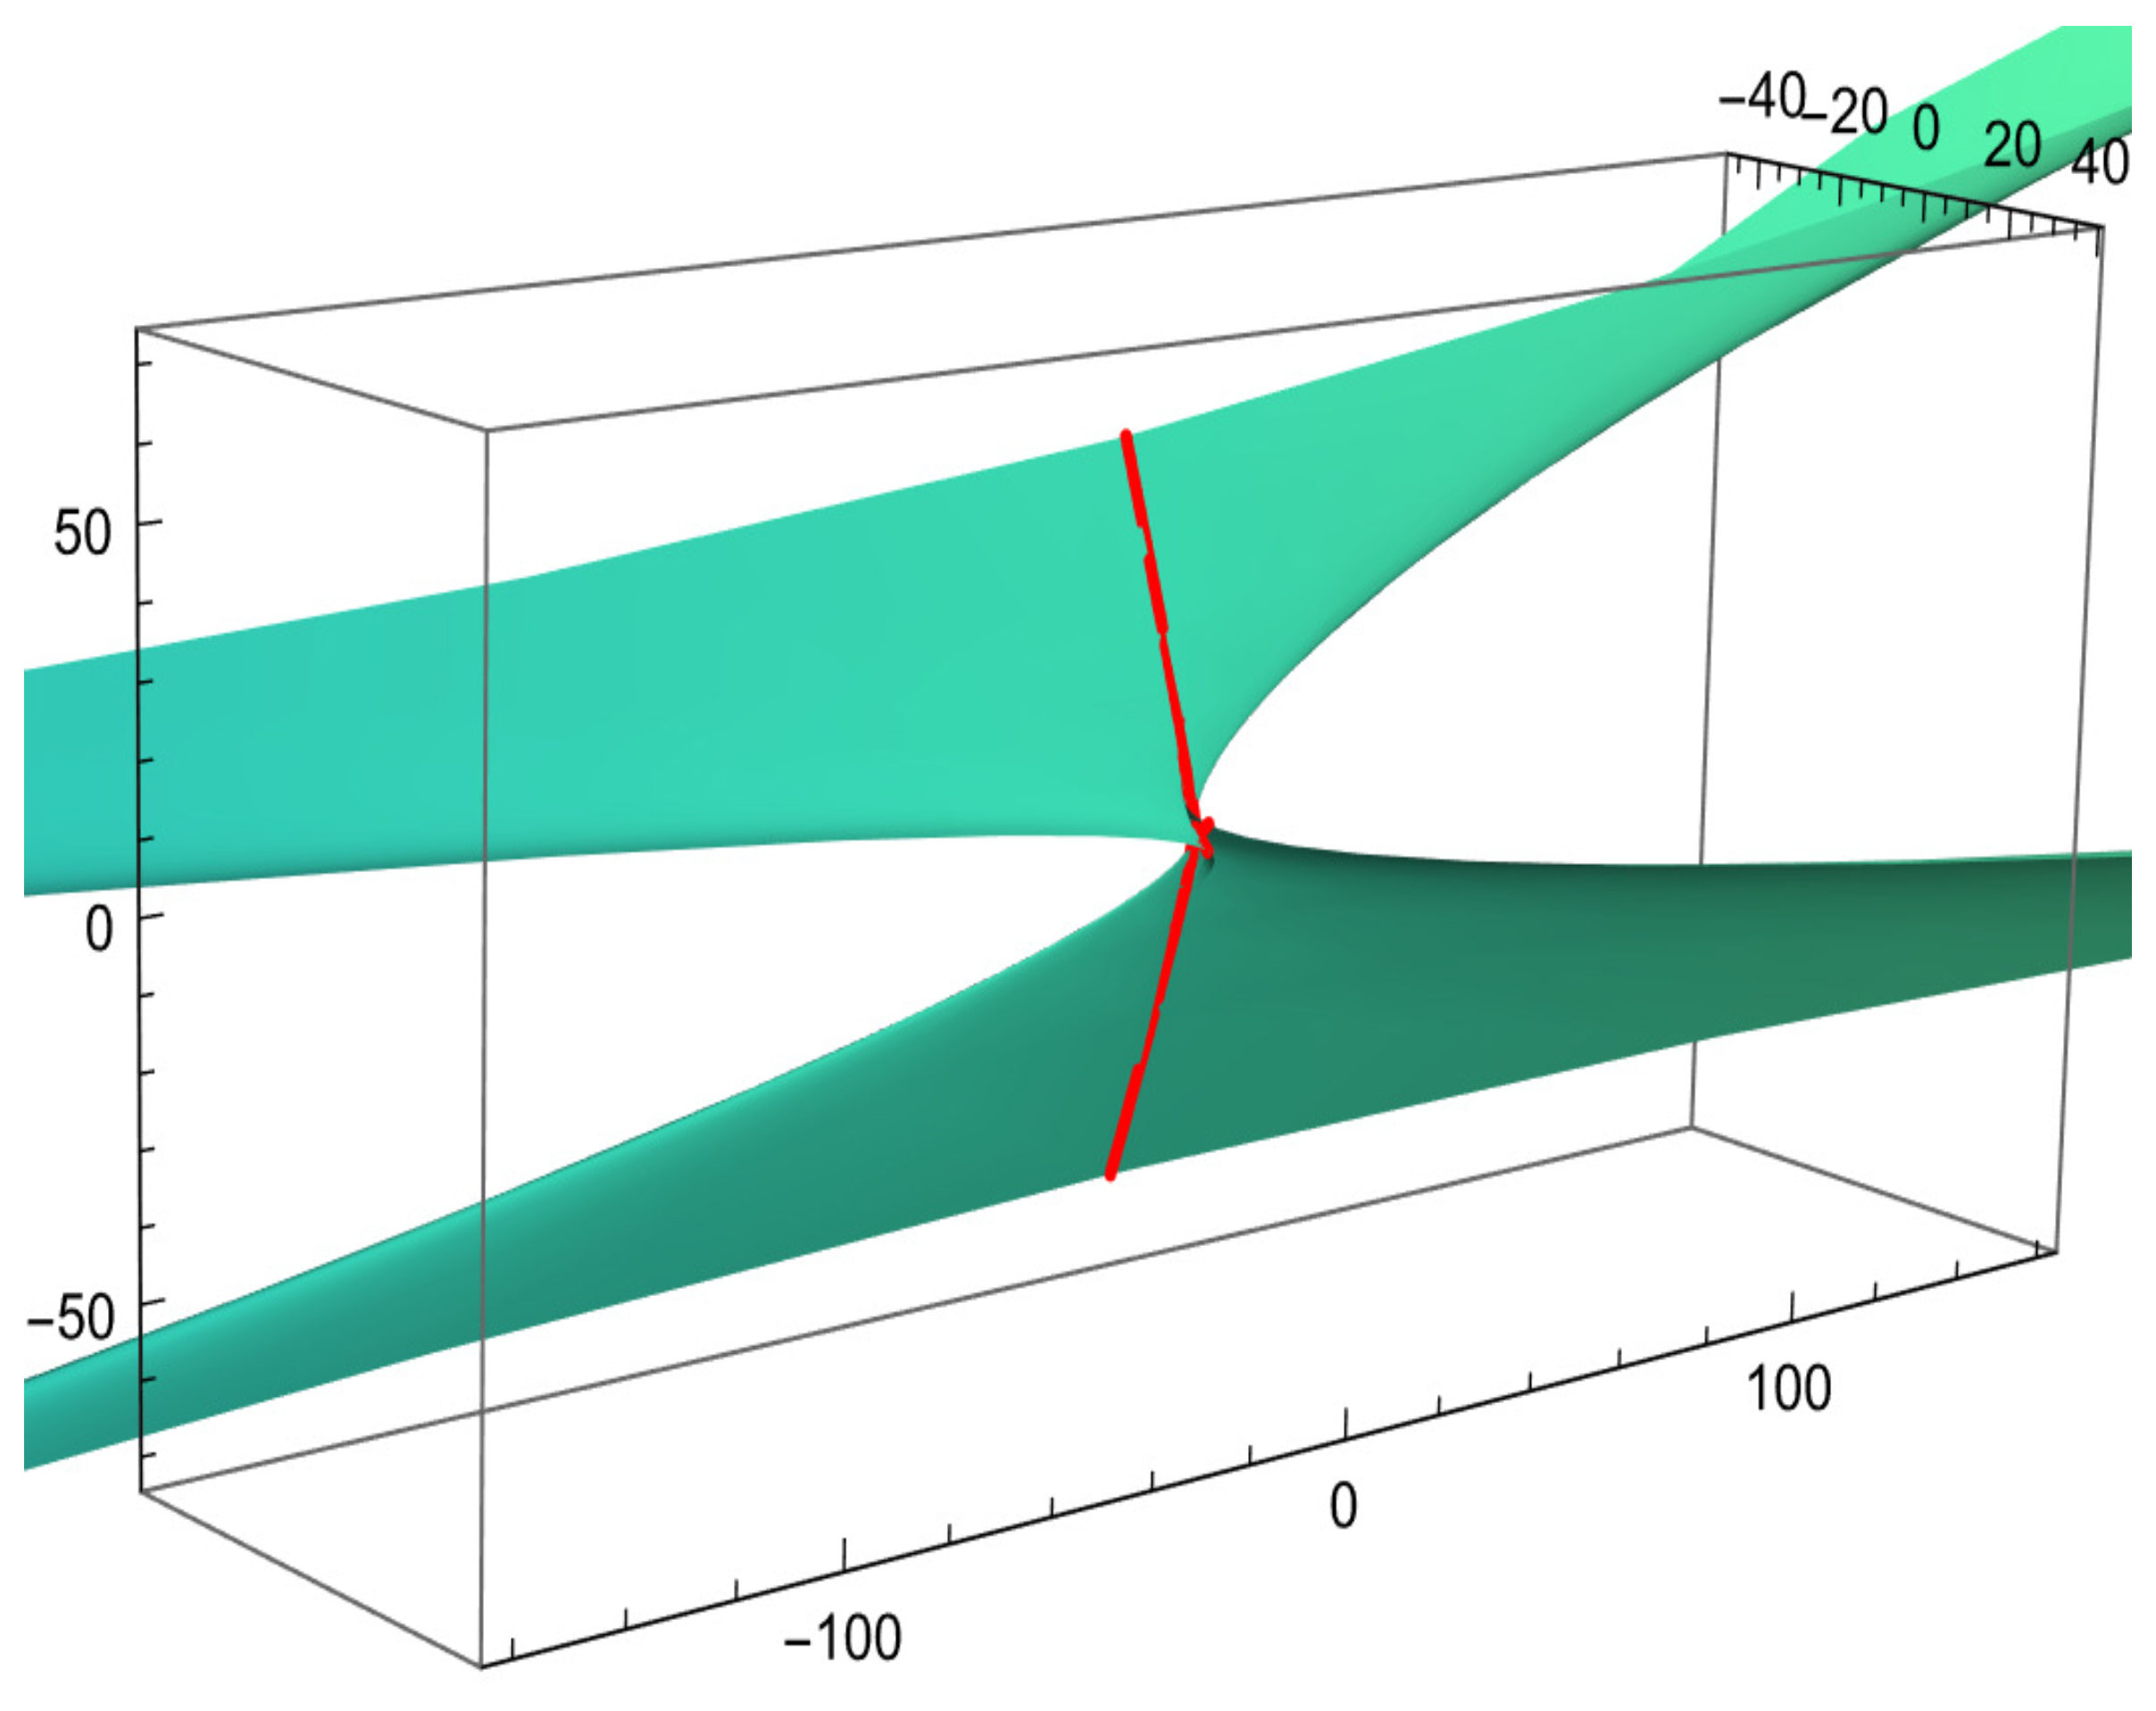
In parallel, the RM Hasimoto surface expressed in terms of the RM Darboux frame itself can be written as (see Figure 3)
Figure 2.
The curvr and the Hasimoto surface , and .
Figure 3.
The curvr and the RM Hasimoto surface , and .
The tangent vectors of are expressed as
The metric coefficients of the surface are obtained as
The unit normal vector is written in the RM Darboux basis as
Now the second fundamental form coefficients
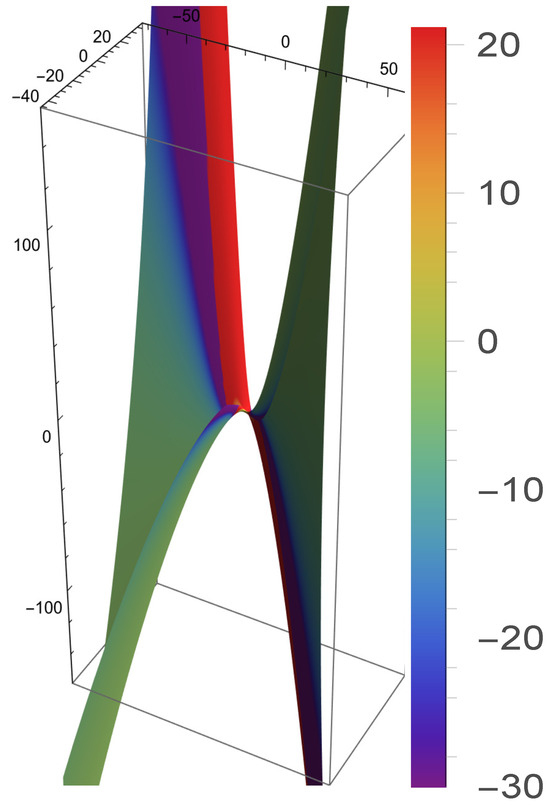
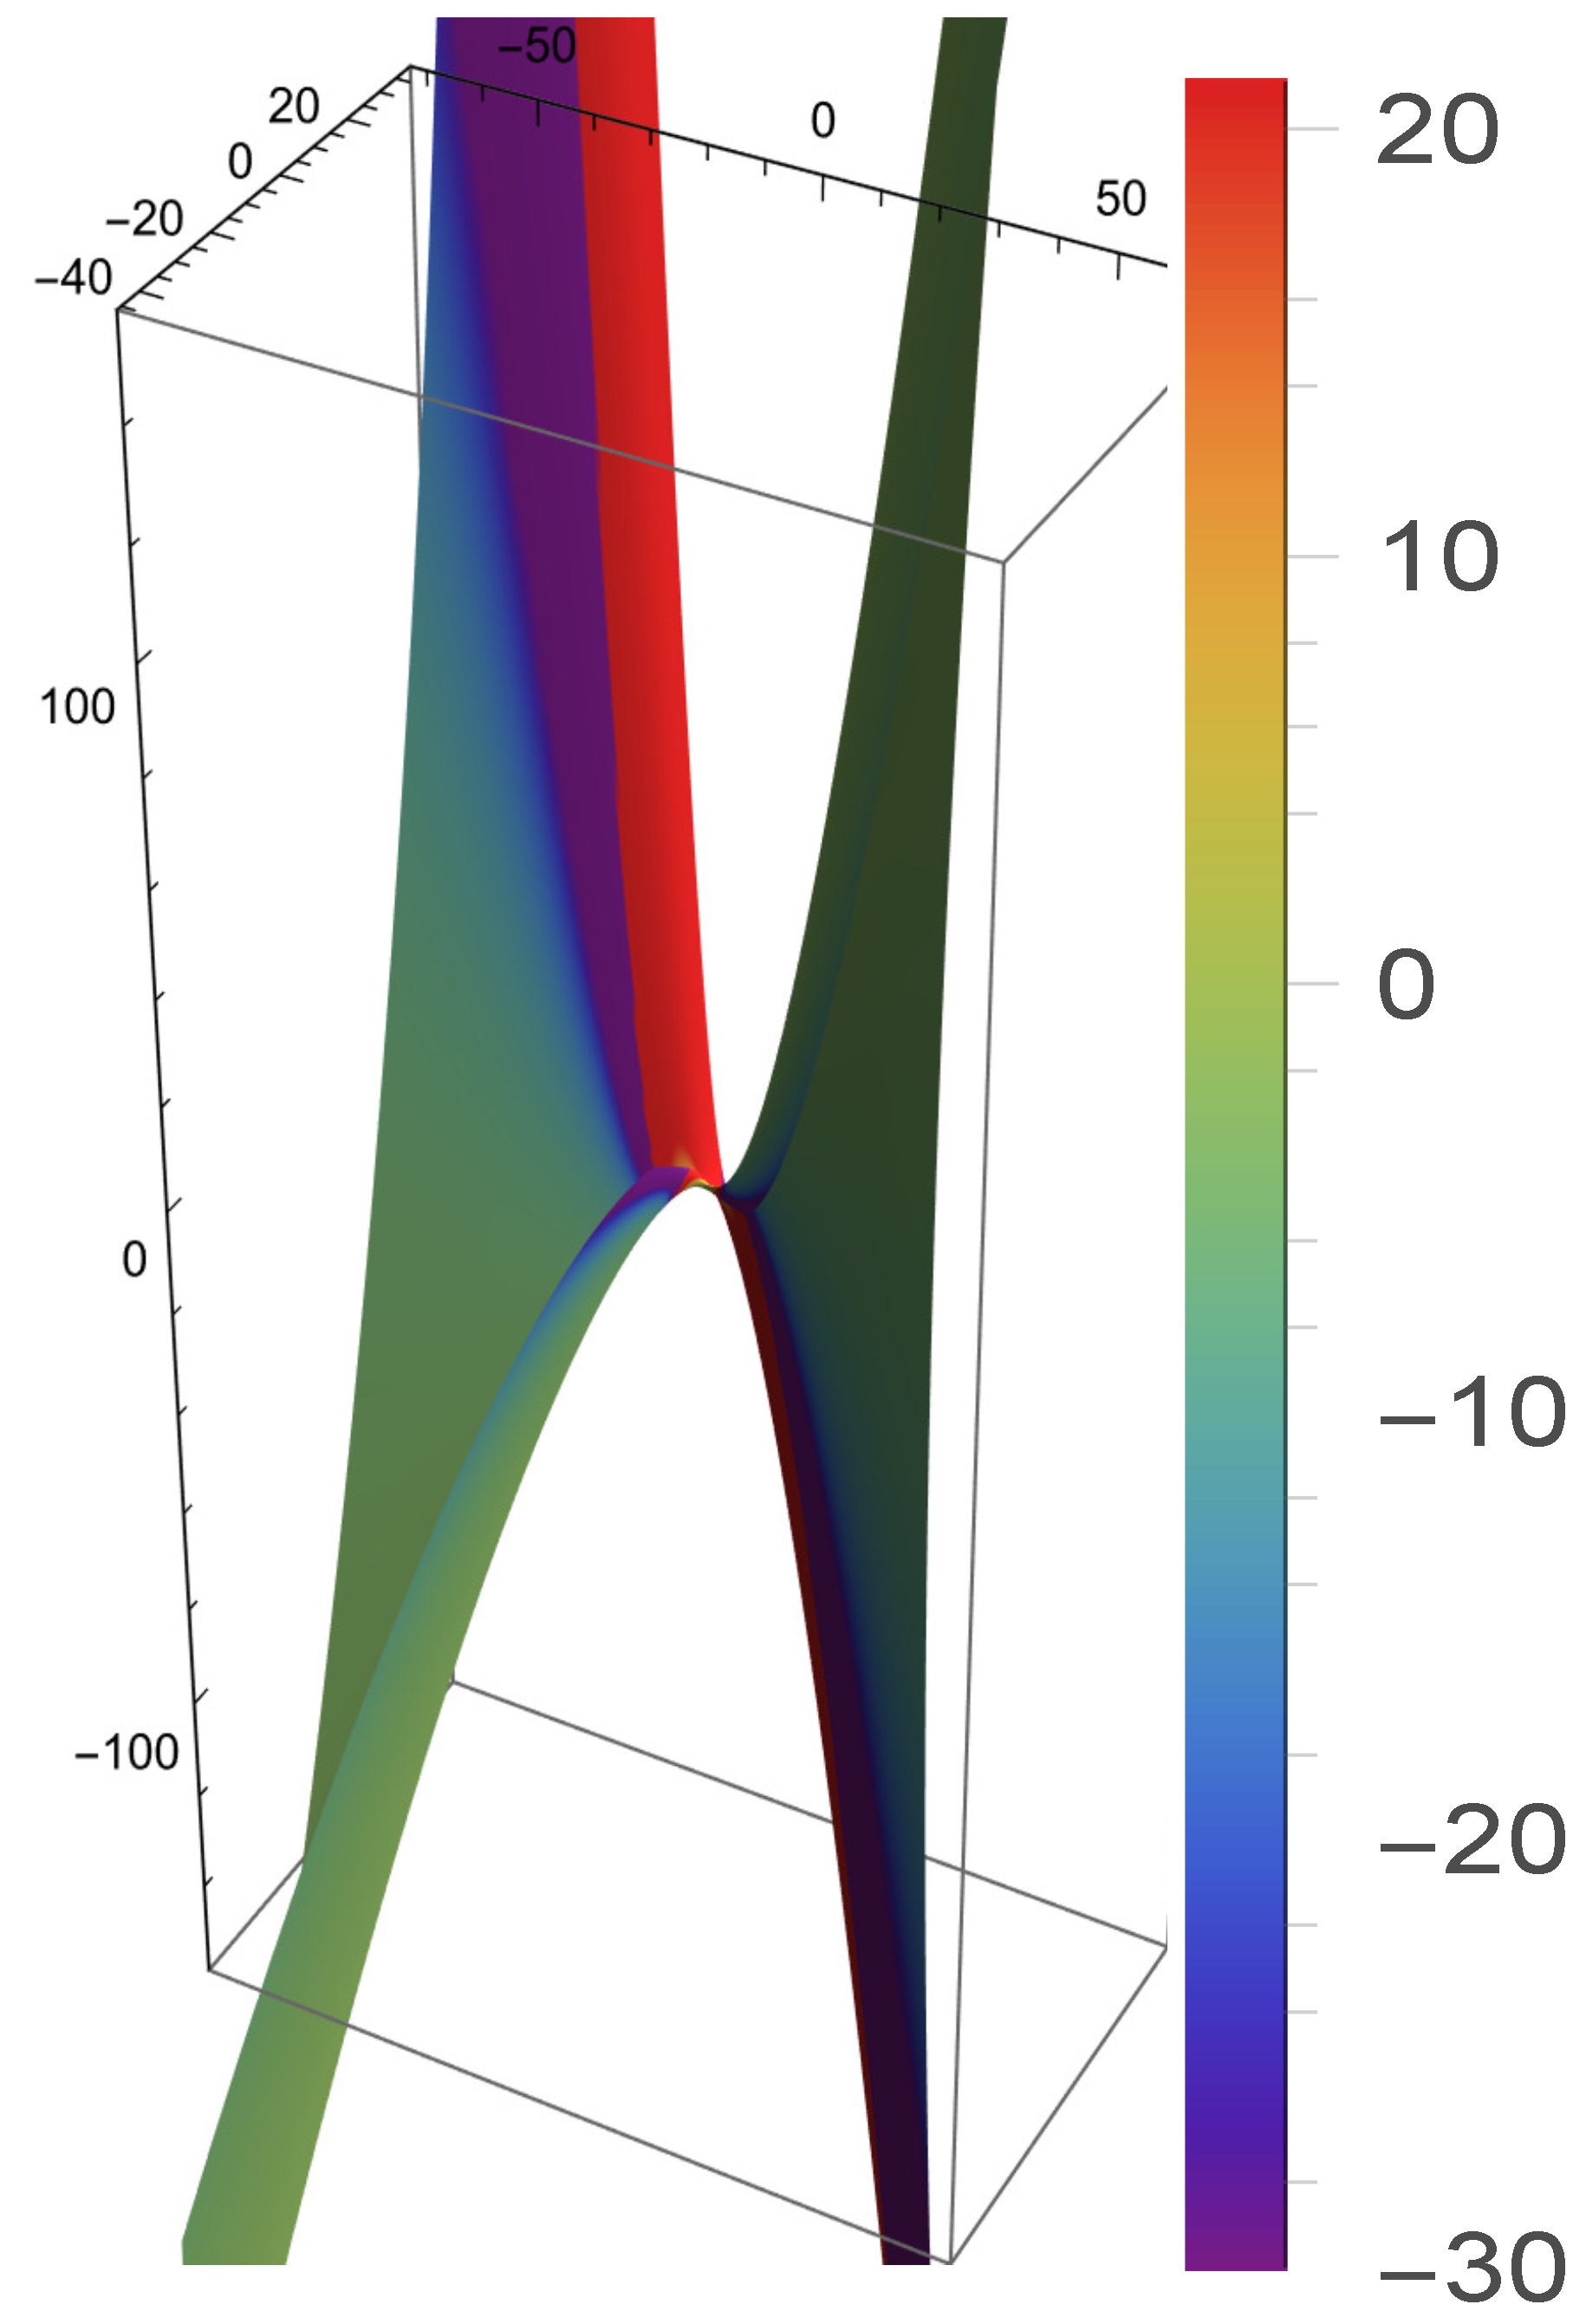
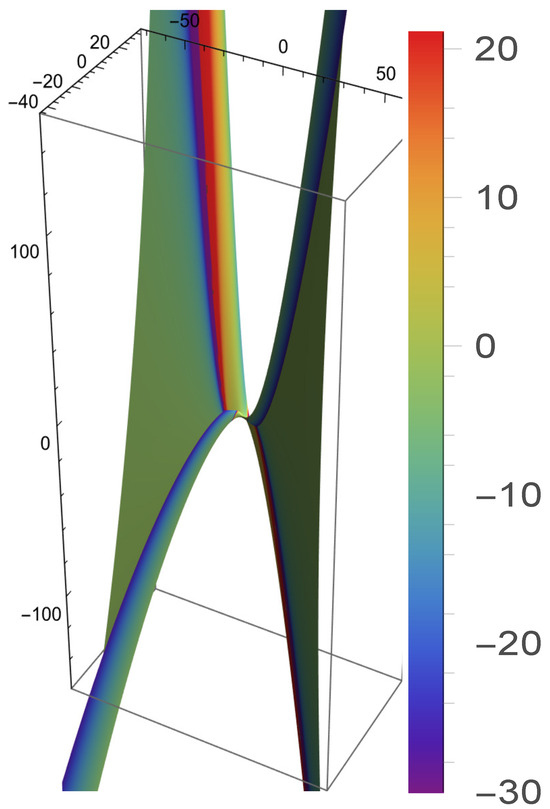
The Gaussian curvature and mean curvature can be expressed as (see Figure 4 and Figure 5)
Figure 4.
Gaussian curvature .
Figure 5.
Mean curvature .
5. Conclusions
In this work, we have developed a new class of Hasimoto-inspired surfaces, termed RM Hasimoto surfaces, by employing the rotation-minimizing Darboux frame along timelike and spacelike curves in Minkowski 3-space. This formulation avoids the torsional difficulties present in Frenet- or Darboux-based constructions, leading to simplified expressions for the fundamental forms, Gaussian and mean curvatures, and a clearer classification of key parameter curves. Beyond their static geometry, we derived the evolution laws of these surfaces under the localized induction flow and identified associated conservation structures, thereby reinforcing their connection to physical models such as vortex filaments, soliton dynamics, and Lorentzian field configurations. Worked examples further illustrate the efficiency of the RM approach, confirming its ability to sharpen geometric characterizations and broaden the applicability of Hasimoto-type surfaces. Altogether, the RM framework provides both theoretical clarity and practical versatility, opening new avenues for research in Lorentzian differential geometry and its physical applications.
Author Contributions
Data curation, E.S., S.S., M.M. and H.M.B.; Formal analysis, E.S., S.S., M.M. and H.M.B.; Funding acquisition, E.S.; Methodology, E.S., S.S., M.M. and H.M.B.; Software, E.S., M.M. and H.M.B.; Writing—original draft, E.S., S.S., M.M. and H.M.B.; Writing—review and editing, E.S., S.S., M.M. and H.M.B. All authors have read and agreed to the published version of the manuscript.
Funding
This work was supported and funded by the Deanship of Scientific Research at Imam Mohammad Ibn Saud Islamic University (IMSIU) (grant number IMSIU-DDRSP-RP25).
Data Availability Statement
Data are contained within the article. Further inquiries can be directed to the corresponding author.
Conflicts of Interest
The authors declare no conflicts of interest.
References
- Da Rios, L.S. On the motion of an unbounded fluid with a vortex filament of any shape. Rend. Circ. Mat. Palermo. 1906, 22, 117–135. [Google Scholar] [CrossRef] [Scilit]
- Ricca, R.L. Rediscovery of da Rios equations. Nature 1991, 352, 561–572. [Google Scholar] [CrossRef] [Scilit]
- Hasimoto, H. A soliton on a vortex filament. J. Fluid Mech. 1972, 51, 477–485. [Google Scholar] [CrossRef] [Scilit]
- Uby, L.; Isichenko, M.B.; Yankov, V.V. Vortex filament dynamics in plasmas and superconductors. Phys. Rev. 1995, 52, 932. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Ivey, T.A. Helices, Hasimoto surfaces and Bäcklund transformations. Canad. Math. Bull. 2000, 43, 427–439. [Google Scholar] [CrossRef] [Scilit]
- Kaymanli, G.U.; Ekici, C.; Koçak, M. On the Hasimoto surfaces in Euclidean 3-space. J. Sci. Arts 2022, 22, 883–890. [Google Scholar] [CrossRef] [Scilit]
- Hamouda, E.; Moaaz, O.; Cesarano, C.; Askar, S.; Elsharkawy, A. Geometry of Solutions of the Quasi-Vortex Filament Equation in Euclidean 3-Space E3. Mathematics 2022, 10, 891. [Google Scholar] [CrossRef] [Scilit]
- Eren, K. New representation of Hasimoto surfaces with the modified orthogonal frame. Konuralp J. Math. 2022, 10, 69–72. [Google Scholar]
- Erdoğdu, M. Geometry of Hasimoto surfaces in Minkowski 3-space. Int. J. Pure Appl. Math. 2014, 17, 169–181. [Google Scholar] [CrossRef] [Scilit]
- Aiki, M. The Hasimoto transformation for a finite-length vortex filament and its application. SIAM J. Math. Anal. 2023, 55, 1234–1256. [Google Scholar] [CrossRef] [Scilit]
- Abdel-Aziz, H.S.; Serry, H.M.; El-Adawy, F.M.; Saad, M.K. Geometry and evolution of Hasimoto surface in Minkowski 3-space. PLoS ONE 2024, 19, e0294310. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Savci, U.Z.; Yilmaz, S. The Darboux rotation axis & special curves according to rotation minimizing frame in Minkowski 3- Space. Prespacetime J. 2018, 9, 232–244. [Google Scholar]
- García, R.; Jiménez, J. On the use of rotation minimizing frames for curves in Lorentzian spaces. Mathematics 2020, 8, 1412. [Google Scholar]
- Özdemir, M.; Tosun, M. Rotation Minimizing Frames in Lorentz-Minkowski 3-Space. Commun. Fac. Sci. Univ. Ank. Ser. A1 Math. Stat. 2021, 70, 757–770. [Google Scholar]
- Ali, A.T.; Turgut, M. Rotation Minimizing Darboux Frame and Applications to Surfaces in Minkowski Space. Results Math. 2023, 78, 153. [Google Scholar]
- Solouma, E.; Al-Dayel, I.; Khan, M.A.; Lazer, Y.A. Characterization of imbricate-ruled surfaces via rotation-minimizing Darboux frame in Minkowski 3-space . AIMS Math. 2024, 9, 13028–13042. [Google Scholar] [CrossRef] [Scilit]
- Solouma, E.; Saber, S.; Baskonus, H.M. Exploring harmonic evolute geometries derived from tubular surfaces in Minkowski 3-space using the RM Darboux frame. Mathematics 2025, 13, 2329. [Google Scholar] [CrossRef] [Scilit]
- Lopez, R.; Sipus, Z.M.; Gajcic, L.P.; Protrka, I. Harmonic evolutes of B-scrolls with constant mean curvature in Lorentz-Minkowski space. Int. J. Geom. Methods Mod. Phys. 2019, 16, 1950076. [Google Scholar] [CrossRef] [Scilit]
- O’Neill, B. Semi-Riemannian Geometry with Applications to Relativity; Academic Press: New York, NY, USA, 1983. [Google Scholar]
- Chen, B.Y. Pseudo-Riemannian Geometry, δ-invariants and Applications; World Scientific: Singapore, 2011. [Google Scholar]
- Do Carmo, M.P. Differential Geometry of Curves and Surfaces: Revised and Updated Second Edition; Courier Dover Publications: Miniola, NY, USA, 2016. [Google Scholar]
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2025 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).