


Abstract
This paper addresses the issue of practical fixed-time tracking control for a class of strict-feedback nonlinear systems subject to external disturbances, while ensuring flexible prescribed performance. First, a fixed-time disturbance observer is designed to estimate the unknown external disturbances. The primary advantage of the proposed fixed-time disturbance observer lies in its capability to estimate both the disturbance itself and its higher-order derivatives in fixed time. In addition, various prescribed performance behaviors can be realized via a set of function transformations, merely by modifying certain critical parameters, without the need to redesign the controller. It is shown that, under the proposed control strategy, the system output can track the reference signal in fixed time, and the tracking error always remains within the prescribed performance boundaries. Finally, the simulation results are provided to demonstrate the feasibility and effectiveness of the proposed control scheme.
MSC:
93C10
1. Introduction
Due to the diversity and complexity of system models, the design of controllers for nonlinear systems has attracted considerable attention over the past few decades, and has found wide application in various practical systems such as robotic manipulators [1] and electromagnetic suspension maglev trains [2]. Owing to its ability to handle a broad class of nonlinearities and its constructive nature, backstepping has become one of the cornerstone techniques in nonlinear control theory [3,4]. In addition to their inherent nonlinear characteristics, nonlinear systems are often subject to unknown external disturbances, which further complicate the control problem and can significantly degrade system performance or even destabilize the closed-loop system. The literature [5] proposes a control strategy utilizing Genetic Algorithms, aiming to suppress dynamic disturbances and thereby improve positioning accuracy and reduce errors. As a result, the control of nonlinear systems in the presence of external disturbances has emerged as a prominent research focus. To address the influence of disturbances, especially mismatched ones, literature [6] proposed a novel control approach based on the command filtered backstepping method. In literature [7], a smooth function characterized by a positively integrable time-varying profile was incorporated into the controller to compensate for unknown time-varying parameters and uncertain disturbances. In literature [8], an extended state observer was designed by incorporating both adaptive control and a nonlinear disturbance observer, aiming to handle parameter uncertainties, unobservable states, and external disturbances individually, thus enhancing the system’s tracking performance. Although literature [9] introduced a continuous finite-time disturbance observer capable of estimating both disturbances and their derivatives, the observer’s convergence time was still influenced by the initial states of the system. Therefore, the investigation of fixed-time disturbance observer holds significant research value.
In many practical control applications, the system output is often required to satisfy certain transient and steady-state performance specifications, such as predefined bounds on overshoot, convergence rate, and steady-state error. To this end, prescribed performance control has emerged as an effective framework that explicitly incorporates performance constraints into the control design process [10,11]. The work in literature [12] combined adaptive fixed-time control with a prescribed performance framework to guarantee that the tracking error was confined within a desired bound in fixed time. A series of functional transformations were embedded into the control framework in literature [13] to achieve flexible prescribed tracking performance. The major advantage of the work in literature [13] lay in its ability to achieve various prescribed performance behaviors by adjusting a few key parameters through a series of functional transformations, without the need to redesign the controller. It is worth noting that the work in literature [13] did not address the effect of external disturbances, which may limit its applicability in disturbance-prone environments.
Motivated by the above analysis and discussion, a fixed-time control scheme is developed for strict-feedback nonlinear systems subject to external disturbances with flexible prescribed performance. The primary contributions of this paper can be summarized as follows:
- (1)
- In contrast to literature [14], the designed fixed-time disturbance observer is capable of precisely estimating the disturbance, its derivative, and higher-order variations, which contributes to improved tracking performance and robustness. Meanwhile, unlike the finite-time disturbance observer in literature [9], whose settling time depends on the initial conditions of the system, the convergence time of observation error in the proposed fixed-time disturbance observer is independent of the system’s initial conditions.
- (2)
- The proposed fixed-time control strategy not only guarantees tracking within a fixed time but also enables various prescribed performance behaviors through a set of function transformations under a fixed control framework.
2. Problem Statement and Preliminaries
Problem Statement
Consider the following strict-feedback nonlinear system:
where ∈. ∈, and are the state vector, the control input and the system output, respectively. is the known bounded smooth time-varying function. is the unknown external disturbance. Then, the reference signal is defined as .
Control objective: The control objective of this paper is to develop the control algorithm for the nonlinear system (1) such that
- (i)
- the tracking error is guaranteed to remain within the various prescribed performance bounds;
- (ii)
- all the signals in the closed-loop are bounded;
- (iii)
- the observer errors converge to zero in fixed time.
To achieve the above control objective, some essential definitions, assumptions and lemmas are introduced to facilitate the subsequent design and analysis.
Definition 1.
, .
Definition 2.
A continuous function , for some positive constant σ and a positive constant ρ, is defined as a time-varying scaling function, if it satisfies:
- (i)
- , , , and ;
- (ii)
- , and .
Assumption 1
([15]). The reference signal , along with its -th order time derivatives are known, continuous and bounded.
Assumption 2
([9]). It is assumed that the external disturbance originates from the following system:
where ∈, is an unknown constant and the matrices and are defined as
where are known constants.
Lemma 1
([16]). Consider a scalar system:
where is a definitly positive smooth function, , , , , and . Then, the system exhibits practical fixed-time stability and the settling time is bounded by
where ρ is a design parameter, which satisfies . In addition, The solution’s residual set for system (4) can be expressed as follows:
Lemma 2
([17]). For , design the following switch function:
where and k is a arbitrary small positive constant. If exists, exists.
Lemma 3
([18]). For , and , , it follows that:
Lemma 4
([19]). A fixed-time observer is constructed as
where is the observer error, which satisfies and is the ideal signal. satisfy the relations , where for an arbitrary positive constant ϵ. Then, the exponents satisfy the relations , where . The observer gains and for are appropriately selected to guarantee that the matrices P and Q are Hurwitz. Under these conditions, within the fixed time , the observer error will approach zero.
And the convergence time T satisfies
where , , and . , , and represent the positive definite non-singular matrices, which satisfy and .
3. Results
3.1. Prescribed Performance Behavior and Function Transformation
Based on the time-varying scaling function introduced in Definition 2, the corresponding prescribed performance behaviors are formulated as:
where represents the initial value of e, and . The positive constants and satisfy . satisfies and is defined as a mapping from to . Moreover, and its time derivatives up to the -th order are known, continuous, and bounded.
Case 1: When and are set as and , the initial values of can be calculated as and . is a positive constant. Then, for , one can obtain
Case 2: When and are chosen as , the initial values of can be calculated as . Hence, it yields
Case 3: When and are chosen as , the initial values of can be calculated as . In this context, one can obtain
Since the prescribed performance behavior described in (12) cannot be directly utilized in the subsequent controller design, a series of function transformations is introduced.
3.1.1. Error-Dependent Function
A function is constructed with respect to the tracking error e, and the error can be expressed as . Due to the characteristics of , (12) can be transformed into the following form:
3.1.2. Uniform Mapping Function
To provide a unified representation of the two cases in (16), the following function transformation is introduced:
where , , and . Therefore, through two function transformations, the realization of the prescribed performance in (12) is converted into a constraint on , which is summarized in the following lemma:
Lemma 5
([13]). If the designed controller ensures that , then for any initial value satisfying (12), the tracking error will evolve within the prescribed performance bounds for all .
3.1.3. Barrier Function
Based on the definition and properties of , the following tan-type barrier function with respect to is constructed:
Thus, the task of ensuring is equivalent to stabilizing . For the sake of subsequent analysis and controller design, the performance function is selected as .
3.2. Design of Fixed-Time Disturbance Observer
This section presents the construction of a fixed-time disturbance observer to estimate the disturbance and its derivatives within a fixed time. First, to facilitate the subsequent design of fixed-time disturbance observer, some coordinate transformations are formulated as follows:
According to (19), the derivatives of are computed as
where , and .
Then, we define the fixed-time disturbance observer as
where . satisfy the relations , where for an arbitrary positive constant . Then, the exponents satisfy the relations , where . and for are observer gains.
Therefore, the observer error system is expressed as follows:
where .
Theorem 1.
By appropriately selecting the observer gains , , the observation error can be guaranteed to converge to zero in fixed time . Then, the convergence time satisfies
where , , and . , , and represent the positive definite non-singular matrices, which satisfy and .
Proof of Theorem 1.
Based on Lemma 4, the observation error for converges to zero within the fixed time by appropriately selecting the observer gains and such that the following matrices P and Q are Hurwitz, where the matrices P and Q are defined as follows:
□
3.3. Design of Controller
In this section, the controller is designed using the backstepping technology, where the command filter introduced in the preceding section is utilized to facilitate the design.
First, the coordinate transformations are designed as
To solve the issue of “complexity explosion”, design the following command filter:
where , and are positive constants. The virtual control signal is the input of command filter and is the output of command filter.
Then, the compensated tracking error is formulated as:
To compensate for the error induced by the command filter, the subsequent error compensation system is introduced:
where p is chosen such that . b, and for are positive design parameters.
Step 1: Choose the Lyapunov function as
The derivitive of can be computed as
where and .
Then, the virtual controller is deisgned as
where , , and are chosen as positive design parameters.
Step 2: Consider the Lyapunov function defined as . According to (32), the derivative of can be deduced that
Then, the virtual controller is deisgned as
where , , and are positive design parameters.
Step i (3 ≤ i ≤ n − 1): Let the Lyapunov function be defined as
Further, can be calculated as
Likewise, the virtual controller is deisgned as
where , , and are defined as positive design parameters.
Step n: Let be specified as
Then, the control input u and virtual controller is deisgned as
where , , and are positive design parameters.
Further, can be derived as
3.4. Stability Analysis
The following theorem summarizes the main results of the present investigation.
Theorem 2.
Consider the strict-feedback nonlinear system (1) with external disturbances. With the implementation of controller (42), the following results can be guaranteed:
- (i)
- the boundedness of all signals is ensured;
- (ii)
- the output signal y is guaranteed to converge to the reference signal within the fixed time and the tracking error e is guaranteed to evolve within the prescribed performance bounds.
Proof of Theorem 2.
As the compensation signal is incorporated into the closed-loop system, it is essential to guarantee its fixed-time boundedness.
Choose the Lyapunov function as . Then, one can obtain
It has been shown in [20] that there exists a positive constant satisfying . As is known to be bounded, it is guaranteed that holds for some positive constant .
According to Young’s inequality, is computed as
Then, (45) can be calculated as
Based on the fixed-time disturbance observer (21), it can be concluded that the terms and in (47) will converge to zero when the time . Drawing upon the analysis of the three cases of the switching function presented in [17], it can be inferred that
where the parameter k denotes the partition point in the switching function. It follows from Lemma 3 that
where , and .
As established in Lemma 1, the settling time satisfies the following relation
where denotes a positive constant, satisfying . Moreover, by [17], one can obtain
Consequently, the above analysis demonstrates that the output y converges to the reference trajectory in a fixed time , which can be formulated as .
Because of the boundedness of and , it follows that is bounded. Thus, and R are bounded. According to Lemma 5, it is not difficult to demonstrate that there exists a constant such that . When , we have . In other words, h remains bounded. Since , the boundedness of the tracking error can be always ensured. Therefore, the tracking error e can converge to within the prescribed performance bounds. The same conclusion holds for the case of . As the reference signal is bounded, is also bounded.
From (31), we can conclude that the virtual controller is bounded. Since the input of the designed fixed-time command filter (26) is bounded, it means that the output of command filter is also bounded. Consequently, we can conclude that and are bounded. By repeating the above analysis processes up to step n, we can infer that the boundedness of , , and the control signal u for can be guaranteed. Therefore, the overall analysis confirms that all signals of system (1) remain bounded. □
Remark 1.
It can be concluded from the above analysis that the tracking error can be reduced by increasing b or decreasing , and k. The observer gains , and exponents , significantly affect the convergence performance of the disturbance observer. Large gains accelerate convergence but may amplify measurement noise and introduce chattering, while small values yield smoother estimates at the cost of slower response. Similarly, tuning the exponents adjusts the convergence speed across different error ranges. Therefore, these parameters should be selected to balance convergence speed and noise sensitivity based on application requirements.
Remark 2.
The motivation behind this study is to address the challenge of disturbance estimation in strict-feedback nonlinear systems by developing a fixed-time disturbance observer that guarantees the estimation of the disturbance and its higher-order derivatives within a fixed time, independent of initial conditions. In addition, the adoption of flexible prescribed performance design framework enables the realization of diverse performance behaviors, while also simplifying the control algorithm.
4. Simulation Example
The following example, based on a single-link manipulator, is presented to verify the proposed control approach. This system exhibits a strict-feedback nonlinear structure and is subject to external disturbances, aligning well with the problem setting considered in this paper. The corresponding model is described as .
The position, velocity, and acceleration vectors of the single-link manipulator are denoted by q, and , respectively. The parameters M, m, g and l denote the mechanical inertia, link mass, gravitational acceleration and link length, respectively. represents the control torque applied to the link, and d denotes the external disturbance. The reference signal is chosen as .
To simplify the following analysis, we transform the original variables by defining , , and . This coordinate transformation yields the reconstructed system model:
where . The external disturbance d is defined as
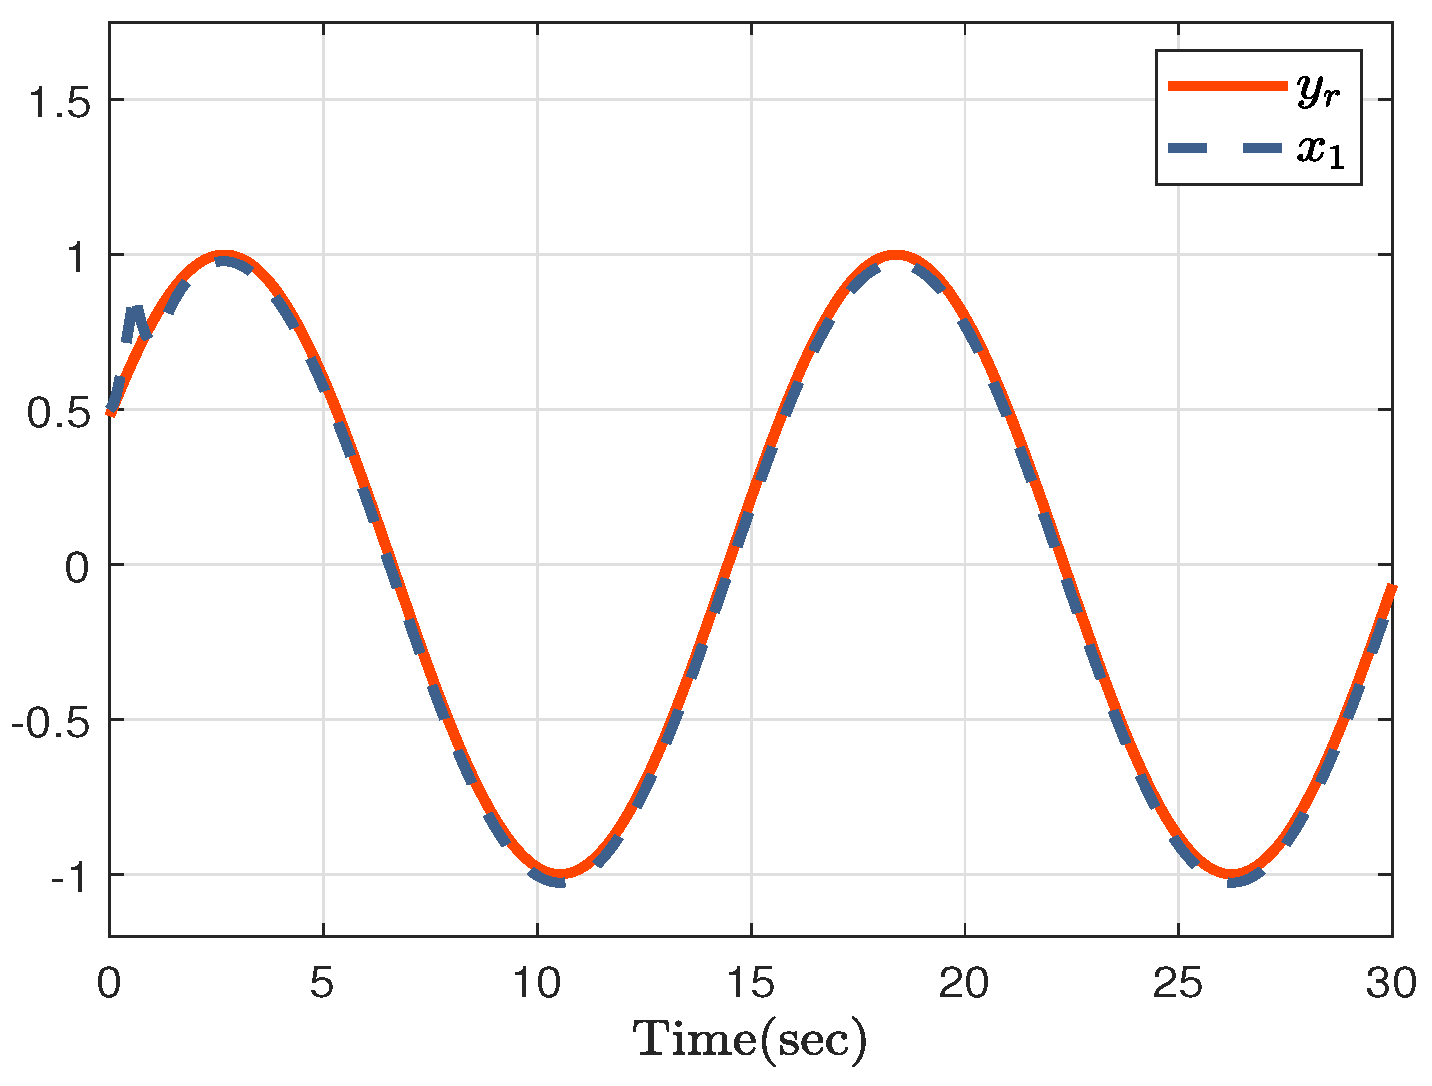
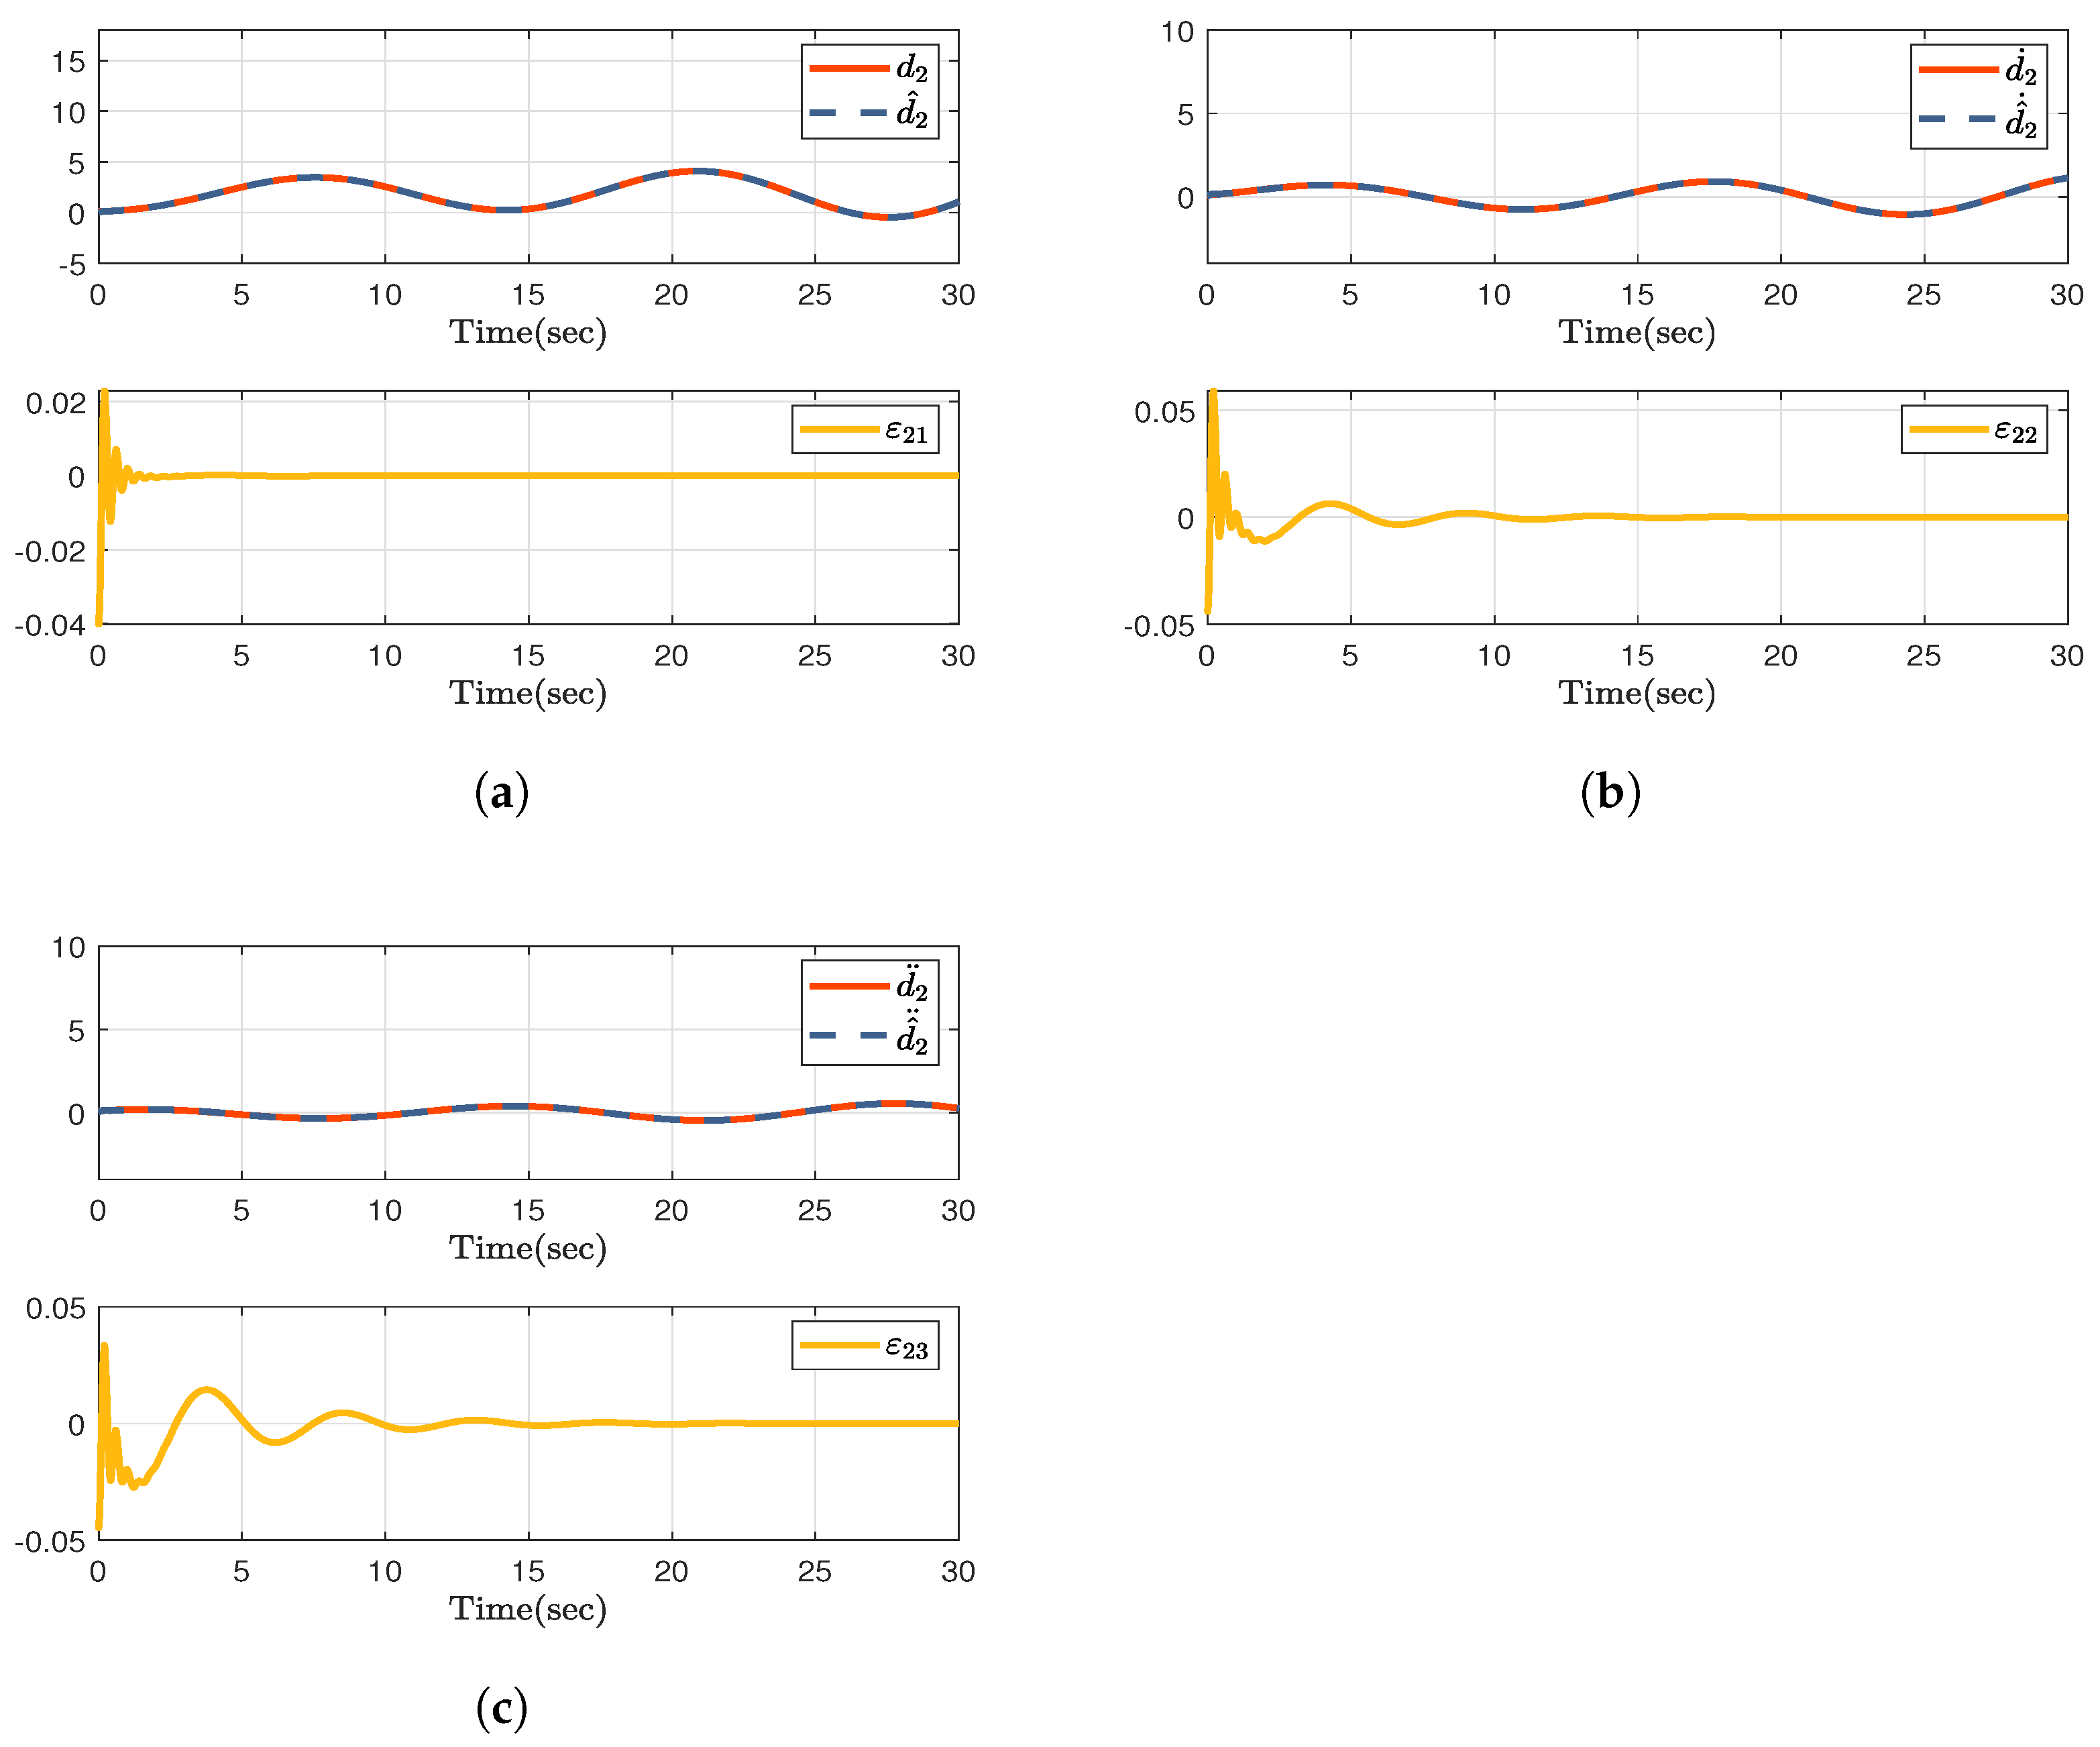
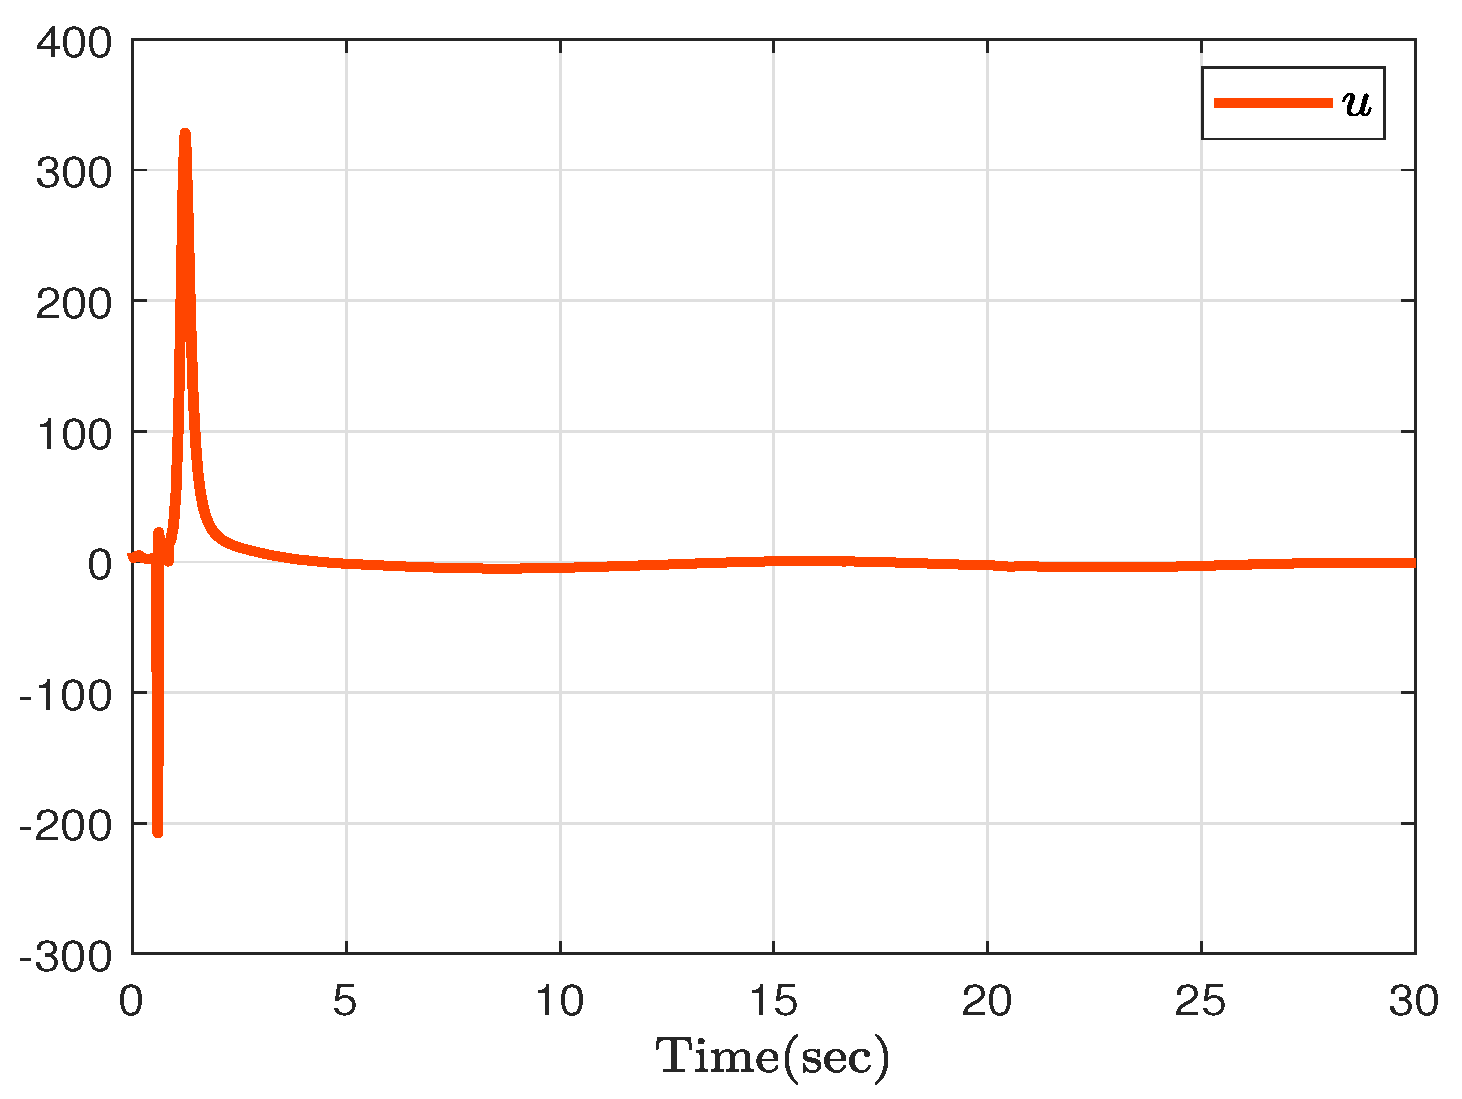
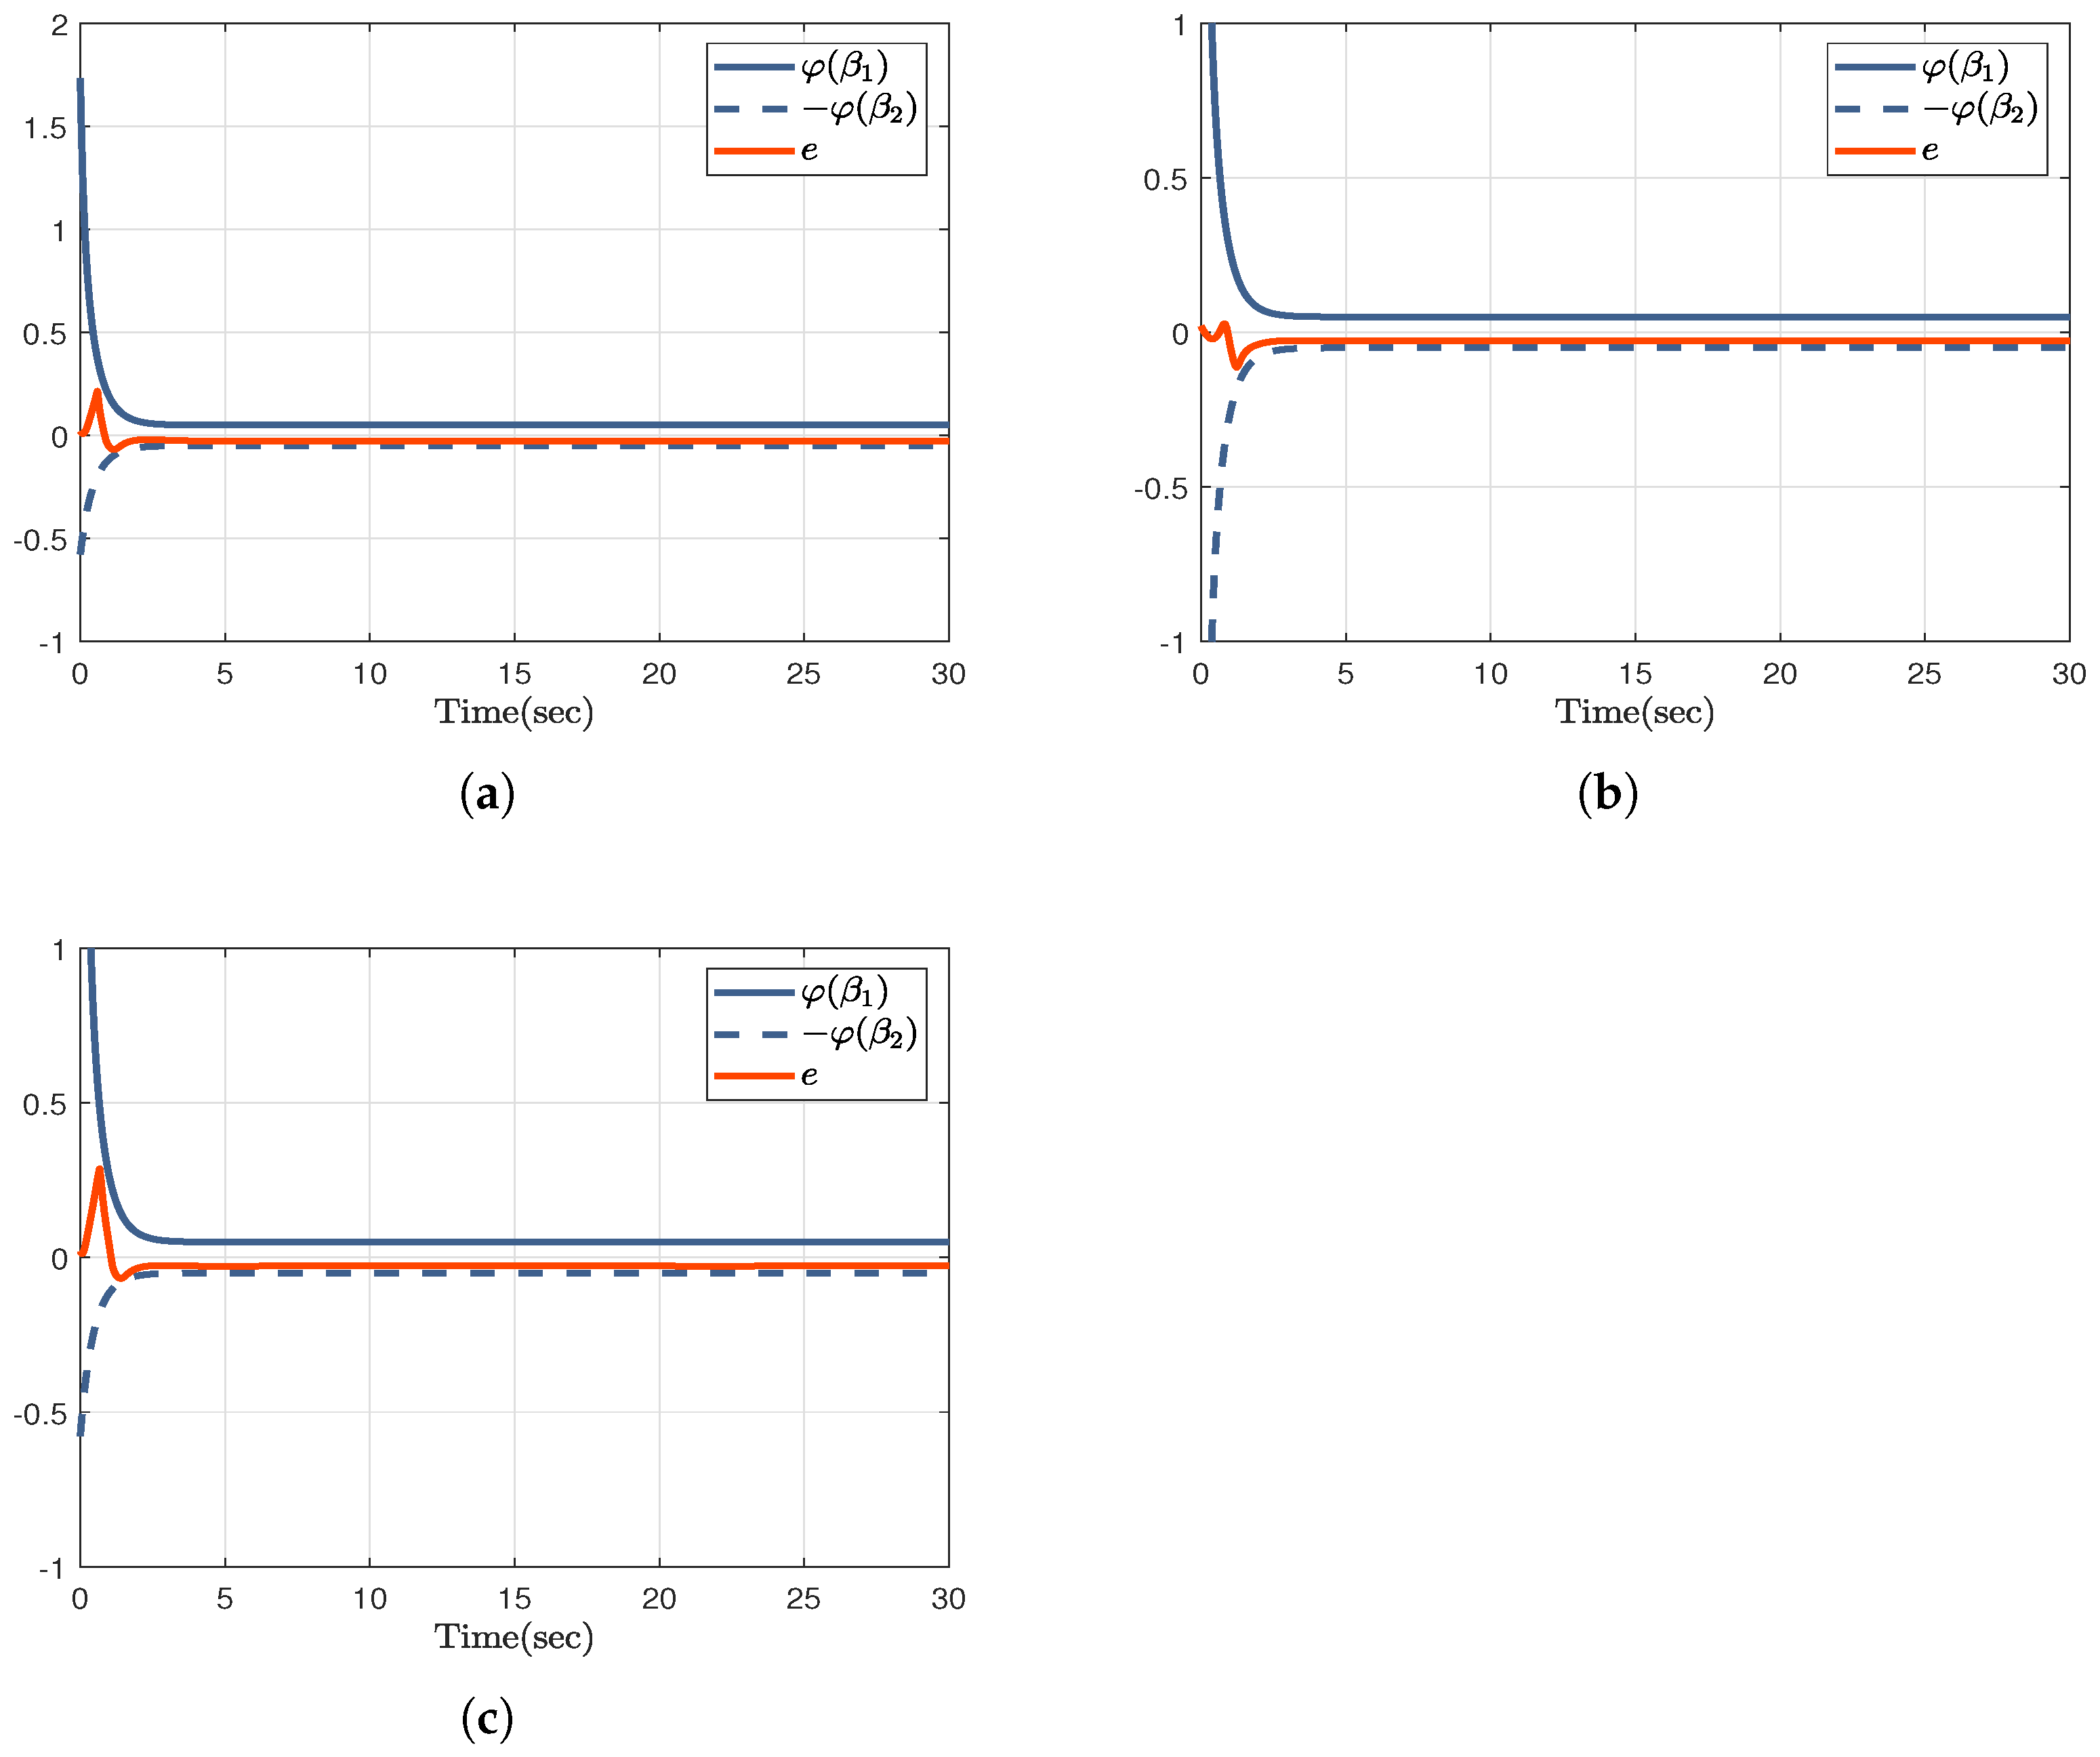
The initial values are selected as . The system parameters are selected as , , and . The disturbance parameters are selected as , , and . Figure 1, Figure 2, Figure 3 and Figure 4 depicts the outcomes of the simulation for system (52).
Figure 1.
Tracking performance.
Figure 2.
(a) Description of observation performance and observer error of d. (b) Description of observation performance and observer error of . (c) Description of observation performance and observer error of .
Figure 3.
Trajectory of the control input u.
Figure 4.
(a) Evolution of tracking error e with and under case 1. (b) Evolution of tracking error e with and under case 2. (c) Evolution of tracking error e with and under case 3.
5. Conclusions
This paper has presented the fixed-time tracking control framework for a class of strict-feedback nonlinear systems subject to unknown external disturbances, with the capability of ensuring flexible prescribed performance. The key component of the proposed approach is the development of a fixed-time disturbance observer, which not only estimates the external disturbances themselves but also their derivatives in fixed time, regardless of the system’s initial conditions. Furthermore, the flexible prescribed performance is incorporated through a set of transformation functions, enabling the control system to accommodate diverse transient and steady-state behaviors to be achieved without modifying the control structure. Under the proposed control scheme, the system output is guaranteed to track the reference signal in fixed time while maintaining the tracking error strictly within various predefined performance bounds. Future work may focus on extending the proposed framework to more complex system settings, such as multi-agent systems, systems with input or state constraints, or those involving event-triggered mechanisms.
Author Contributions
Methodology, X.W.; Software, X.W.; Validation, Y.W.; Investigation, J.H.; Data curation, Y.J.; Writing—original draft, X.W.; Writing—review and editing, B.N. All authors have read and agreed to the published version of the manuscript.
Funding
This research received no external funding.
Data Availability Statement
All data utilized in this study were sourced from publicly available datasets, and the methods for data acquisition are detailed in the cited articles.
Acknowledgments
The authors would like to express their sincere gratitude to the anonymous reviewers and the editorial team for their valuable comments and suggestions, which have significantly improved the quality of this manuscript. The authors also acknowledge the administrative and technical support provided by their respective institutions during the preparation of this work.
Conflicts of Interest
The authors declare no conflicts of interest. The funders had no role in the design of the study; in the collection, analyses, or interpretation of data; in the writing of the manuscript; or in the decision to publish the results.
References
- Hentout, A.; Maoudj, A.; Kouider, A. Shortest Path Planning and Efficient Fuzzy Logic Control of Mobile Robots in Indoor Static and Dynamic Environments. Rom. J. Inf. Sci. Technol. 2024, 2024, 21–36. [Google Scholar] [CrossRef] [Scilit]
- Wen, J.; Wang, F. Stable Levitation of Single-Point Levitation Systemsfor Maglev Trains by Improved Cascade Control. Rom. J. Inf. Sci. Technol. 2024, 27, 348–361. [Google Scholar] [CrossRef] [Scilit]
- Pan, Y.; Ji, W.; Lam, H.-K.; Cao, L. An Improved Predefined-Time Adaptive Neural Control Approach for Nonlinear Multiagent Systems. IEEE Trans. Autom. Sci. Eng. 2024, 21, 6311–6320. [Google Scholar] [CrossRef] [Scilit]
- Pan, Y.; Du, P.; Xue, H.; Lam, H.-K. Singularity-Free Fixed-Time Fuzzy Control for Robotic Systems with User-Defined Performance. IEEE Trans. Fuzzy Syst. 2021, 29, 2388–2398. [Google Scholar] [CrossRef] [Scilit]
- Xin, Z.; Jing, L. Position Tracking Control of an Ultra-Precision Servo System. In Proceedings of the 2022 International Workshop on Advanced Patterning Solutions (IWAPS), Beijing, China, 21–22 October 2022; IEEE: Piscataway, NJ, USA, 2022; pp. 1–3. [Google Scholar]
- Sun, A.; Zhao, L. Command Filtering-based Adaptive Backstepping Control for a Class of Discrete-time Uncertain Nonlinear Systems with Mismatched Disturbances. Int. J. Robust Nonlinear Control 2024, 34, 11513–11528. [Google Scholar] [CrossRef] [Scilit]
- Li, Y.-X. Command Filter Adaptive Asymptotic Tracking of Uncertain Nonlinear Systems with Time-Varying Parameters and Disturbances. IEEE Trans. Autom. Control 2022, 67, 2973–2980. [Google Scholar] [CrossRef] [Scilit]
- Xu, Z.; Liu, Q.; Yao, J. Funnel Function-Based Adaptive Prescribed Performance Output Feedback Control of Hydraulic Systems with Disturbance Observers. ISA Trans. 2023, 136, 701–714. [Google Scholar] [CrossRef] [Scilit]
- Lan, Q.; Li, S.; Yang, J. Finite-time Tracking Control for a Class of Nonlinear Systems with Multiple Mismatched Disturbances. Int. J. Robust Nonlinear Control 2020, 30, 4095–4111. [Google Scholar] [CrossRef] [Scilit]
- Lv, M.; De Schutter, B.; Cao, J.; Baldi, S. Adaptive Prescribed Performance Asymptotic Tracking for High-Order Odd-Rational-Power Nonlinear Systems. IEEE Trans. Autom. Control 2023, 68, 1047–1053. [Google Scholar] [CrossRef] [Scilit]
- Fotiadis, F.; Rovithakis, G.A. Input-Constrained Prescribed Performance Control for High-Order MIMO Uncertain Nonlinear Systems via Reference Modification. IEEE Trans. Autom. Control 2024, 69, 3301–3308. [Google Scholar] [CrossRef] [Scilit]
- Song, X.; Sun, P.; Song, S.; Stojanovic, V. Event-Driven NN Adaptive Fixed-Time Control for Nonlinear Systems with Guaranteed Performance. J. Frankl. Inst. 2022, 359, 4138–4159. [Google Scholar] [CrossRef] [Scilit]
- Li, L.; Zhao, K.; Zhang, Z.; Song, Y. Dual-Channel Event-Triggered Robust Adaptive Control of Strict-Feedback System with Flexible Prescribed Performance. IEEE Trans. Autom. Control 2024, 69, 1752–1759. [Google Scholar] [CrossRef] [Scilit]
- Pang, N.; Wang, X.; Wang, Z. Event-Triggered Adaptive Control of Nonlinear Systems with Dynamic Uncertainties: The Switching Threshold Case. IEEE Trans. Circuits Syst. II Express Br. 2022, 69, 3540–3544. [Google Scholar] [CrossRef] [Scilit]
- Xing, L.; Wen, C. Dynamic Event-Triggered Adaptive Control for a Class of Uncertain Nonlinear Systems. Automatica 2023, 158, 111286. [Google Scholar] [CrossRef] [Scilit]
- Wang, J.; Wang, C.; Liu, Z.; Chen, C.L.P.; Zhang, C. Practical Fixed-Time Adaptive ERBFNNs Event-Triggered Control for Uncertain Nonlinear Systems with Dead-Zone Constraint. IEEE Trans. Syst. Man Cybern Syst. 2024, 54, 342–351. [Google Scholar] [CrossRef] [Scilit]
- Ma, Q.; Xie, Y. Adaptive Event-Triggered Fixed-Time Practical Tracking Control for Uncertain Nonlinear Systems. IEEE Trans. Autom. Control 2024, 69, 5678–5685. [Google Scholar] [CrossRef] [Scilit]
- Xu, H.; Yu, D.; Sui, S.; Zhao, Y.-P.; Chen, C.L.P.; Wang, Z. Nonsingular Practical Fixed-Time Adaptive Output Feedback Control of MIMO Nonlinear Systems. IEEE Trans. Neural Netw. Learn. Syst. 2023, 34, 7222–7234. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Li, X.; Qin, H.; Li, L.; Xue, Y. Fixed-Time Velocity-Free Safe Formation Control of AUVs with Actuator Saturation and Unknown Disturbances. Ocean Eng. 2023, 285, 115361. [Google Scholar] [CrossRef] [Scilit]
- Cui, G.; Yu, J.; Wang, Q.-G. Finite-Time Adaptive Fuzzy Control for MIMO Nonlinear Systems with Input Saturation via Improved Command-Filtered Backstepping. IEEE Trans. Syst. Man Cybern Syst. 2022, 52, 980–989. [Google Scholar] [CrossRef] [Scilit]
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2025 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).