


Abstract
With increasing attention on containment control problems in several areas, we investigate this specific problem which can be more practical. Systems with nonconvex input and position constraints are common but can be strongly nonlinear. A distribute algorithm using a projection operator is proposed to ensure that the control input of every follower remains in a nonconvex set and that all followers stay in the closed set given by leaders. In analysis, a model transformation is proposed, and then we introduce a method utilizing two similar triangles to prove the acceptability of the algorithm. The findings of the research could be pragmatic in robotics, astronautics, and so on. At last, numerical simulations are provided to show the contrast and results.
Keywords:
containment control; multiagent systems; control input constraints; position constraints; switching topologies MSC:
93A16; 93C10
1. Introduction
Over the past few years, containment control has attracted widespread attention due to its potential applications in robotics, astronautics, biology, traffic engineering, etc. The potential of containment control for different areas such as game theory and cyberattack is significant. Numerous works on containment control have been conducted, as in [1,2,3,4,5,6,7,8,9,10,11,12,13,14,15,16,17,18,19,20,21,22,23,24,25,26]. Containment control problem is associated with systems composed of follower agents and multiple leaders. The purpose of containment control is to drive all followers into the convex hull spanned by some static leaders. In [7], the containment control problem was studied when the communication graph was fixed, while containment control with switching topologies where the communication graphs were strongly connected was discussed in [9]. In [16], communication delays for containment control were taken into consideration.
Most of the above works focused on problems in which states and control input of agents had no constraints. In practical situations, agents are always subject to constraints due to physical limitations. For instance, the velocities of vehicles and satellites are constrained to lie in a certain zone. In [27], the consensus problem with convex constraints were studied; the nonconvex constraints of velocity and control input were discussed in [28]. In [29], switching topologies were taken into consideration, which are different from a consensus problem, since the final positions of followers do not converge to one point but a convex hull. The above methods cannot be directly applied to the containment problem with constraints. In [30], the projection operator was used to solve the containment problem with nonconvex control input constraints; the containment problem with position constraints was studied in [31].
In this work, the main task is to take into consideration the control input and position constraints for a containment control problem with switching topologies. A distributed algorithm is proposed to ensure that every follower in the multiagent system can converge into the convex hull spanned by the given leaders. Meanwhile, the position of every follower stays in a closed set given before and the control input does not need to keep lying in a hypercube. In the following, by using model transformation and analyzing the distance from each follower to the convex hull formed by given points, it is shown that the containment control problem can be solved when the directed spanning tree exists in the union of the graphs. In Section 2, the graph theory and multiagent dynamic model id introduced. In Section 3, we describe the main algorithm of the containment control system and the analysis of the main result when applied to a system with nonconvex control input and position constraints. In Section 4, we provide some simulation examples to confirm the feasibility of the algorithm. Finally, concluding notes and further works are remarked in Section 5.
2. Model and Statement
2.1. Preliminaries and Notations
Let represent a directed graph, where is the set of nodes, is the set of edges, and is the weighted adjacency matrix. Each is nonnegative and holds for every agent . Suppose that is an edge of the directed graph, and a directed path is a sequence of edges of the form , otherwise, if the agent can get information from agent at time and .
Notations: The set of r-dimensional real column vectors is represented by ; , , and represent the set of positive real numbers, nonnegative integers, and positive integers, respectively; and denote the Euclidean norm and transpose of the vector , respectively; the projection of vector onto a closed convex set is represented by , where .
2.2. Description of Model
Consider a multiagent system with agents, i.e., followers and leaders. The set of all followers and leaders can be denoted, respectively, by and . Let be the static points of the leaders, which forms the convex hull denoted by .
Each follower is constrained to lie in a convex constraint set that is denoted by . The dynamics of follower is:
where , , and denote the position, the velocity, and the control input of the follower , respectively. In many practical systems, the control input and position state of the agents are always constrained. Next, we give Assumption 1:
Assumption 1.
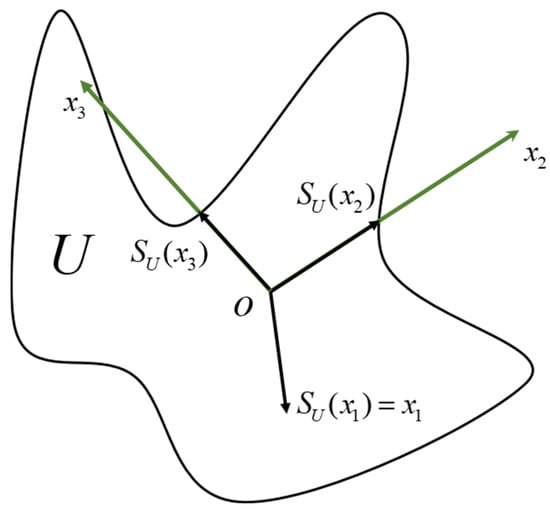
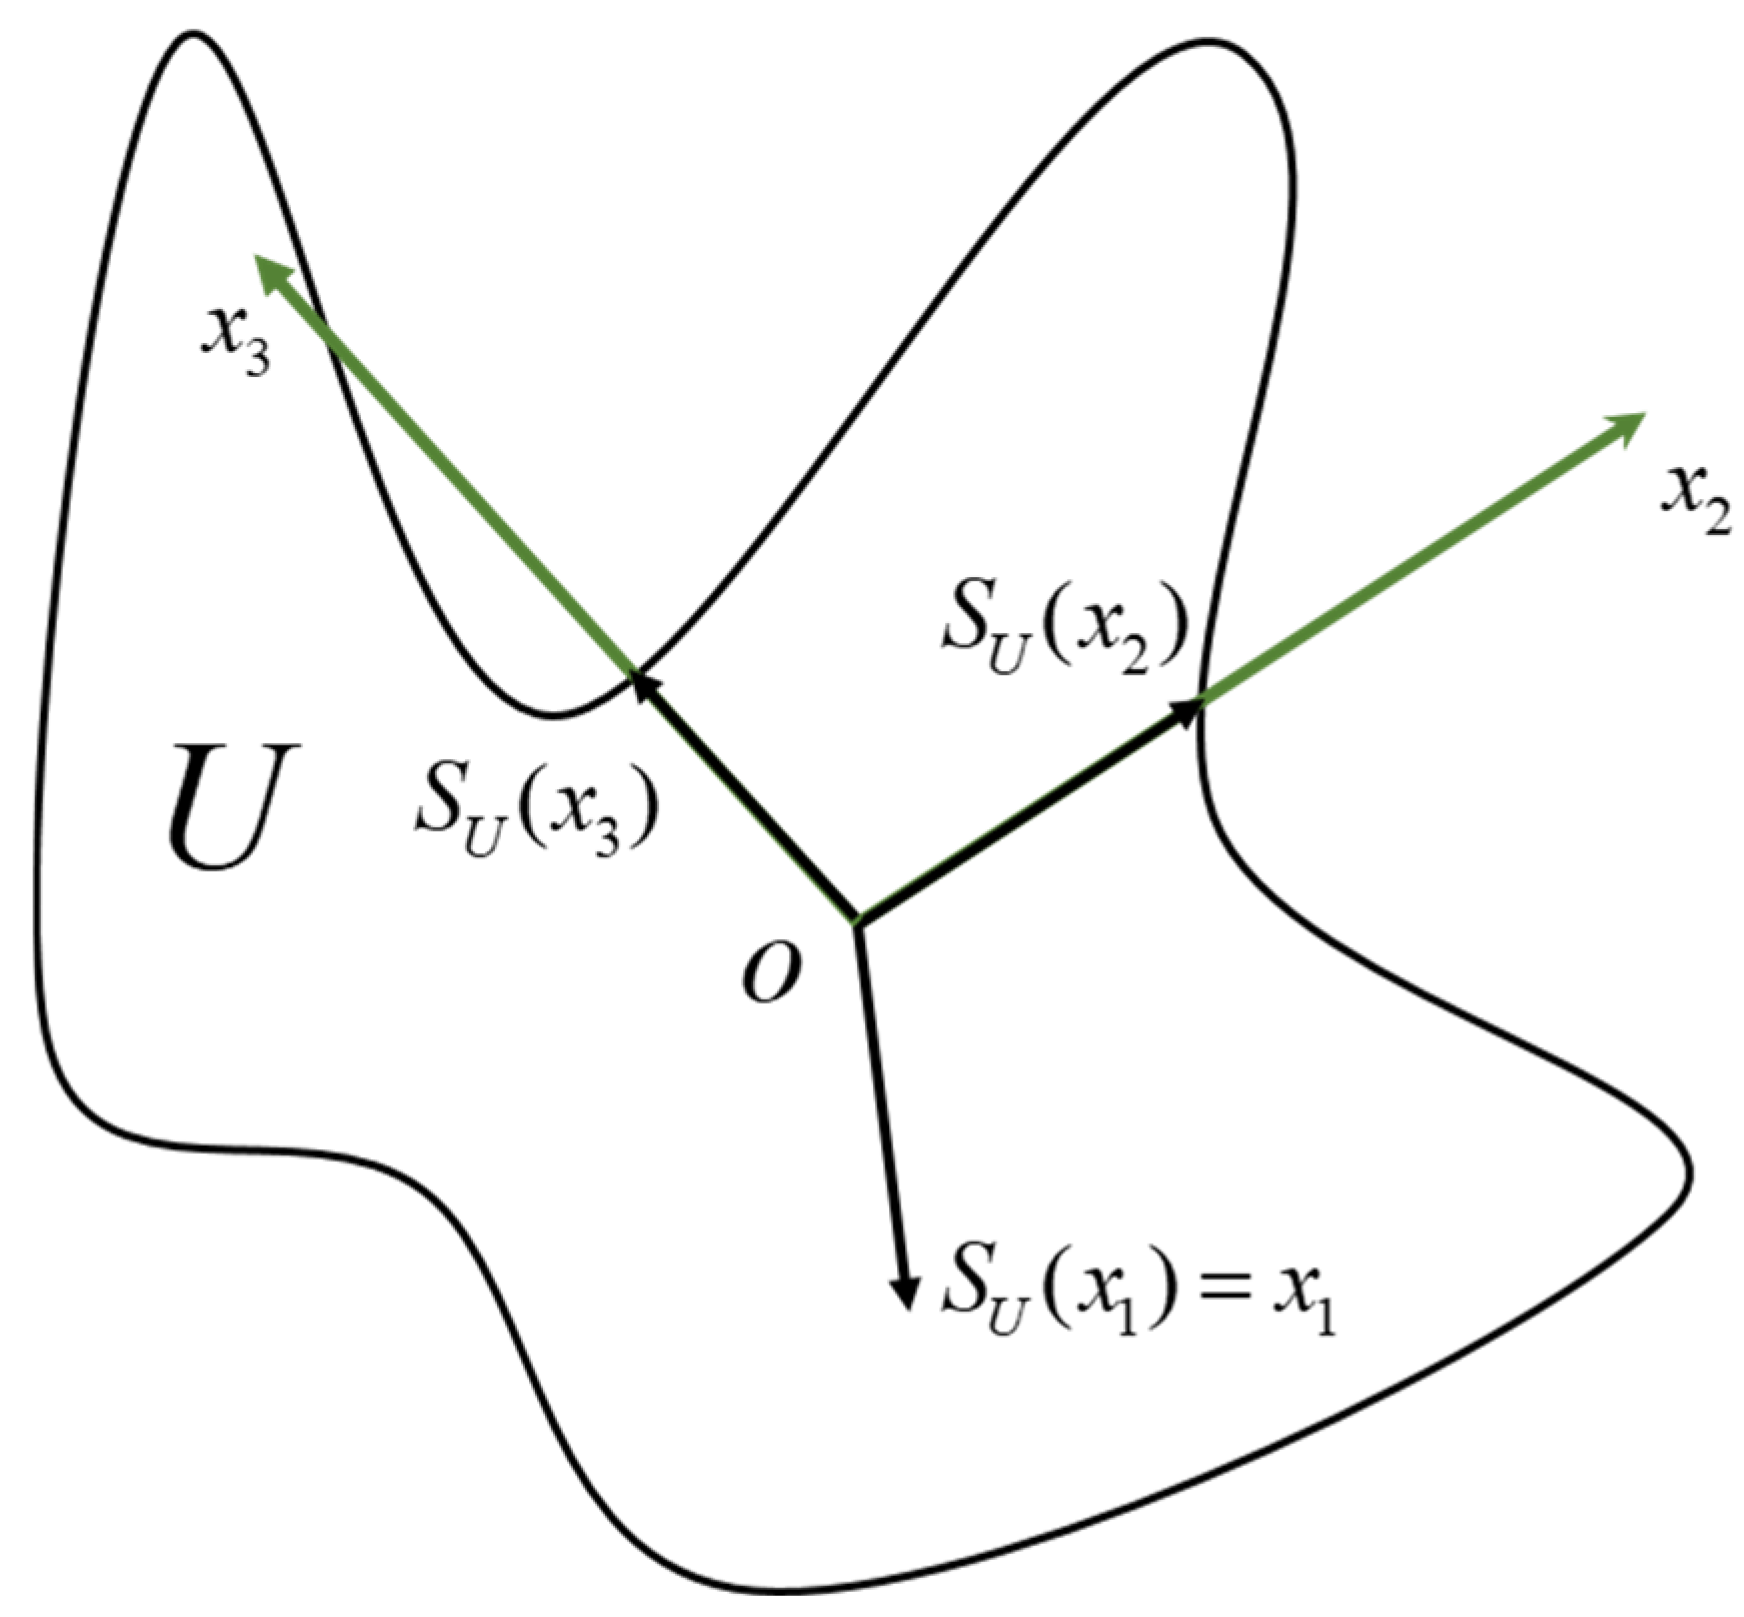
Letforbe the bounded nonempty closed sets, and , whereandare both positive constants. Then,is a constrained operator defined bywhereand, as shown in Figure 1.
Figure 1.
Example of .
Remark 1.
Assumption 1 aims to find a new vectorwhich has the same direction as vectorand satisfiesfor allandfor the bounded nonempty closed set. This assumption shows that every follower can move in all directions. Moreover, the control input of agents are constrained. We suppose each follower to be available in every direction in this paper.
In this paper, our objective is to propose a proper algorithm to drive each follower, whose position and control input are constrained, to move into the convex hull formed by the leaders, that is, for .
3. Main Results
3.1. Containment Control Algorithm
In this section, we would give a nonlinear algorithm to solve the containment control problem with nonconvex control input and position constraints and switching topologies.
for , where represents the velocity damping gain of follower , when follower can receive information directly from one or more leaders at time , and otherwise, and is the set of neighbors of agent . is the edge weight of edge , and it is assumed that if , then is lower bounded by a positive constant. is the convex hull formed by leaders whose information can be received by follower directly at time .
3.2. Analysis of Algorithm
In this section, we provide some necessary assumptions and lemmas to analyze the algorithm given in Section 3.1.
Assumption 2.
Give an infinite sequence of timesatisfyingandwhereand. For every follower, it can be found at least one directed path from given static points to this follower in the union of the graphs in each time interval.
Remark 2.
This assumption ensures that each follower can receive information from the given static leaders directly or indirectly in every time interval.
It is clear that System (1) with (2) has strong nonlinearities due to the existence of the nonconvex control input and position constraints. For this reason, we first introduce a model transformation as follows:
Define
and
Then, System (2) can be rewritten as:
Define
and
for .
Systems (1) and (2) can be transformed into:
for .
Put the definition of (4) into equation, System (5) could be rewritten as:
for .
From System (6), it can be easily found that the sum of the coefficients of and in the first equation and the coefficients of , , , and in the other equation are both equal to 1, which means the existence of destroys the linearity of with and , with , , , and . Hence, the next step is to remove when . Give the following definition:
and
for . Then, (6) could be transformed as:
for .
Assumption 3.
andfor some constant.
Remark 3.
This assumption could be satisfied easily. By using the operatordefined in Assumption 1, the termsandcan be redefined asand, where. As the definition of, we define thatand. It is clear that the two terms can be expressed asand, where. Then, it can be similarly proven thatandare lower bounded by a positive constant with the discussion in Lemma 1.
Lemma 1.
Under Assumption 4 and the definition of operator, we have that if, there existssuch that:
forand, where.
Proof of Lemma 1.
From the definition of , it is apparently that and when , and otherwise. Define . From the definition of difference, there is:
Considering the property of , it can be easily deduced that . Given all this and the condition of Lemma 1, we have:
When , which is , is a sufficiently small constant, can be obtained under the condition of this lemma. Therefore, there exists a constant such that for all . From the assumption of Lemma 1 that , we have . Then, we get for all . Since that can be arbitrarily small, holds, for all . □
Assumption 4.
Suppose that,,for,, for all and .
Remark 4.
This assumption gives the design rules of the algorithm parameters. The parametercan be selected by the following steps:
- (1)
- Select the value ofsuch thatandfor two constantsand.
- (2)
- Select the values of each nonzeroandsuch thatfor each.
Lemma 2
[32].Letdenote a nonempty closed convex set.and scalarssatisfying. It follows.
Lemma 3
[33].Considering a closed convex set, for anyand all, inequalities,andhold.
In order to eliminate , we present the following lemmas.
Lemma 4.
Under Assumption 4, the following statements stand for alland all:
- (1)
- and;
- (2)
- ,,.
Proof of Lemma 4.
- (1)
- As the definition in (7), and , for all and all . It follows thatNote that and , it is obviously that .
- (2)
- Under Assumption 4, and . It can be deduced that . According to the definition of , we have for some constant . In the proof of Lemma 4(1), . Thus, ; also under and Lemma 1, it shows that . □
Lemma 5.
Under Assumptions 4 and 5, the following two inequalities hold for alland all:
Proof of Lemma 5.
- (1)
- Let for . Since , we havefor .From Lemma 3, we havefor .Then, we use Lemma 2. It can transform to:for .
- (2)
- Notice that , , and . It follows thatfor .Because , it follows thatfor . □
Lemma 6.
Under Assumption 4, the following inequality:
holds for alland all.
Proof of Lemma 6.
Let for . It can be easily observed that for .
- When , for . Now, it should be proven that when , for .
- Define for convenience, and it is clear that .
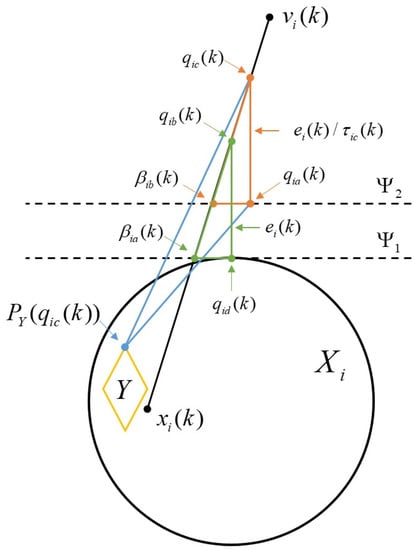
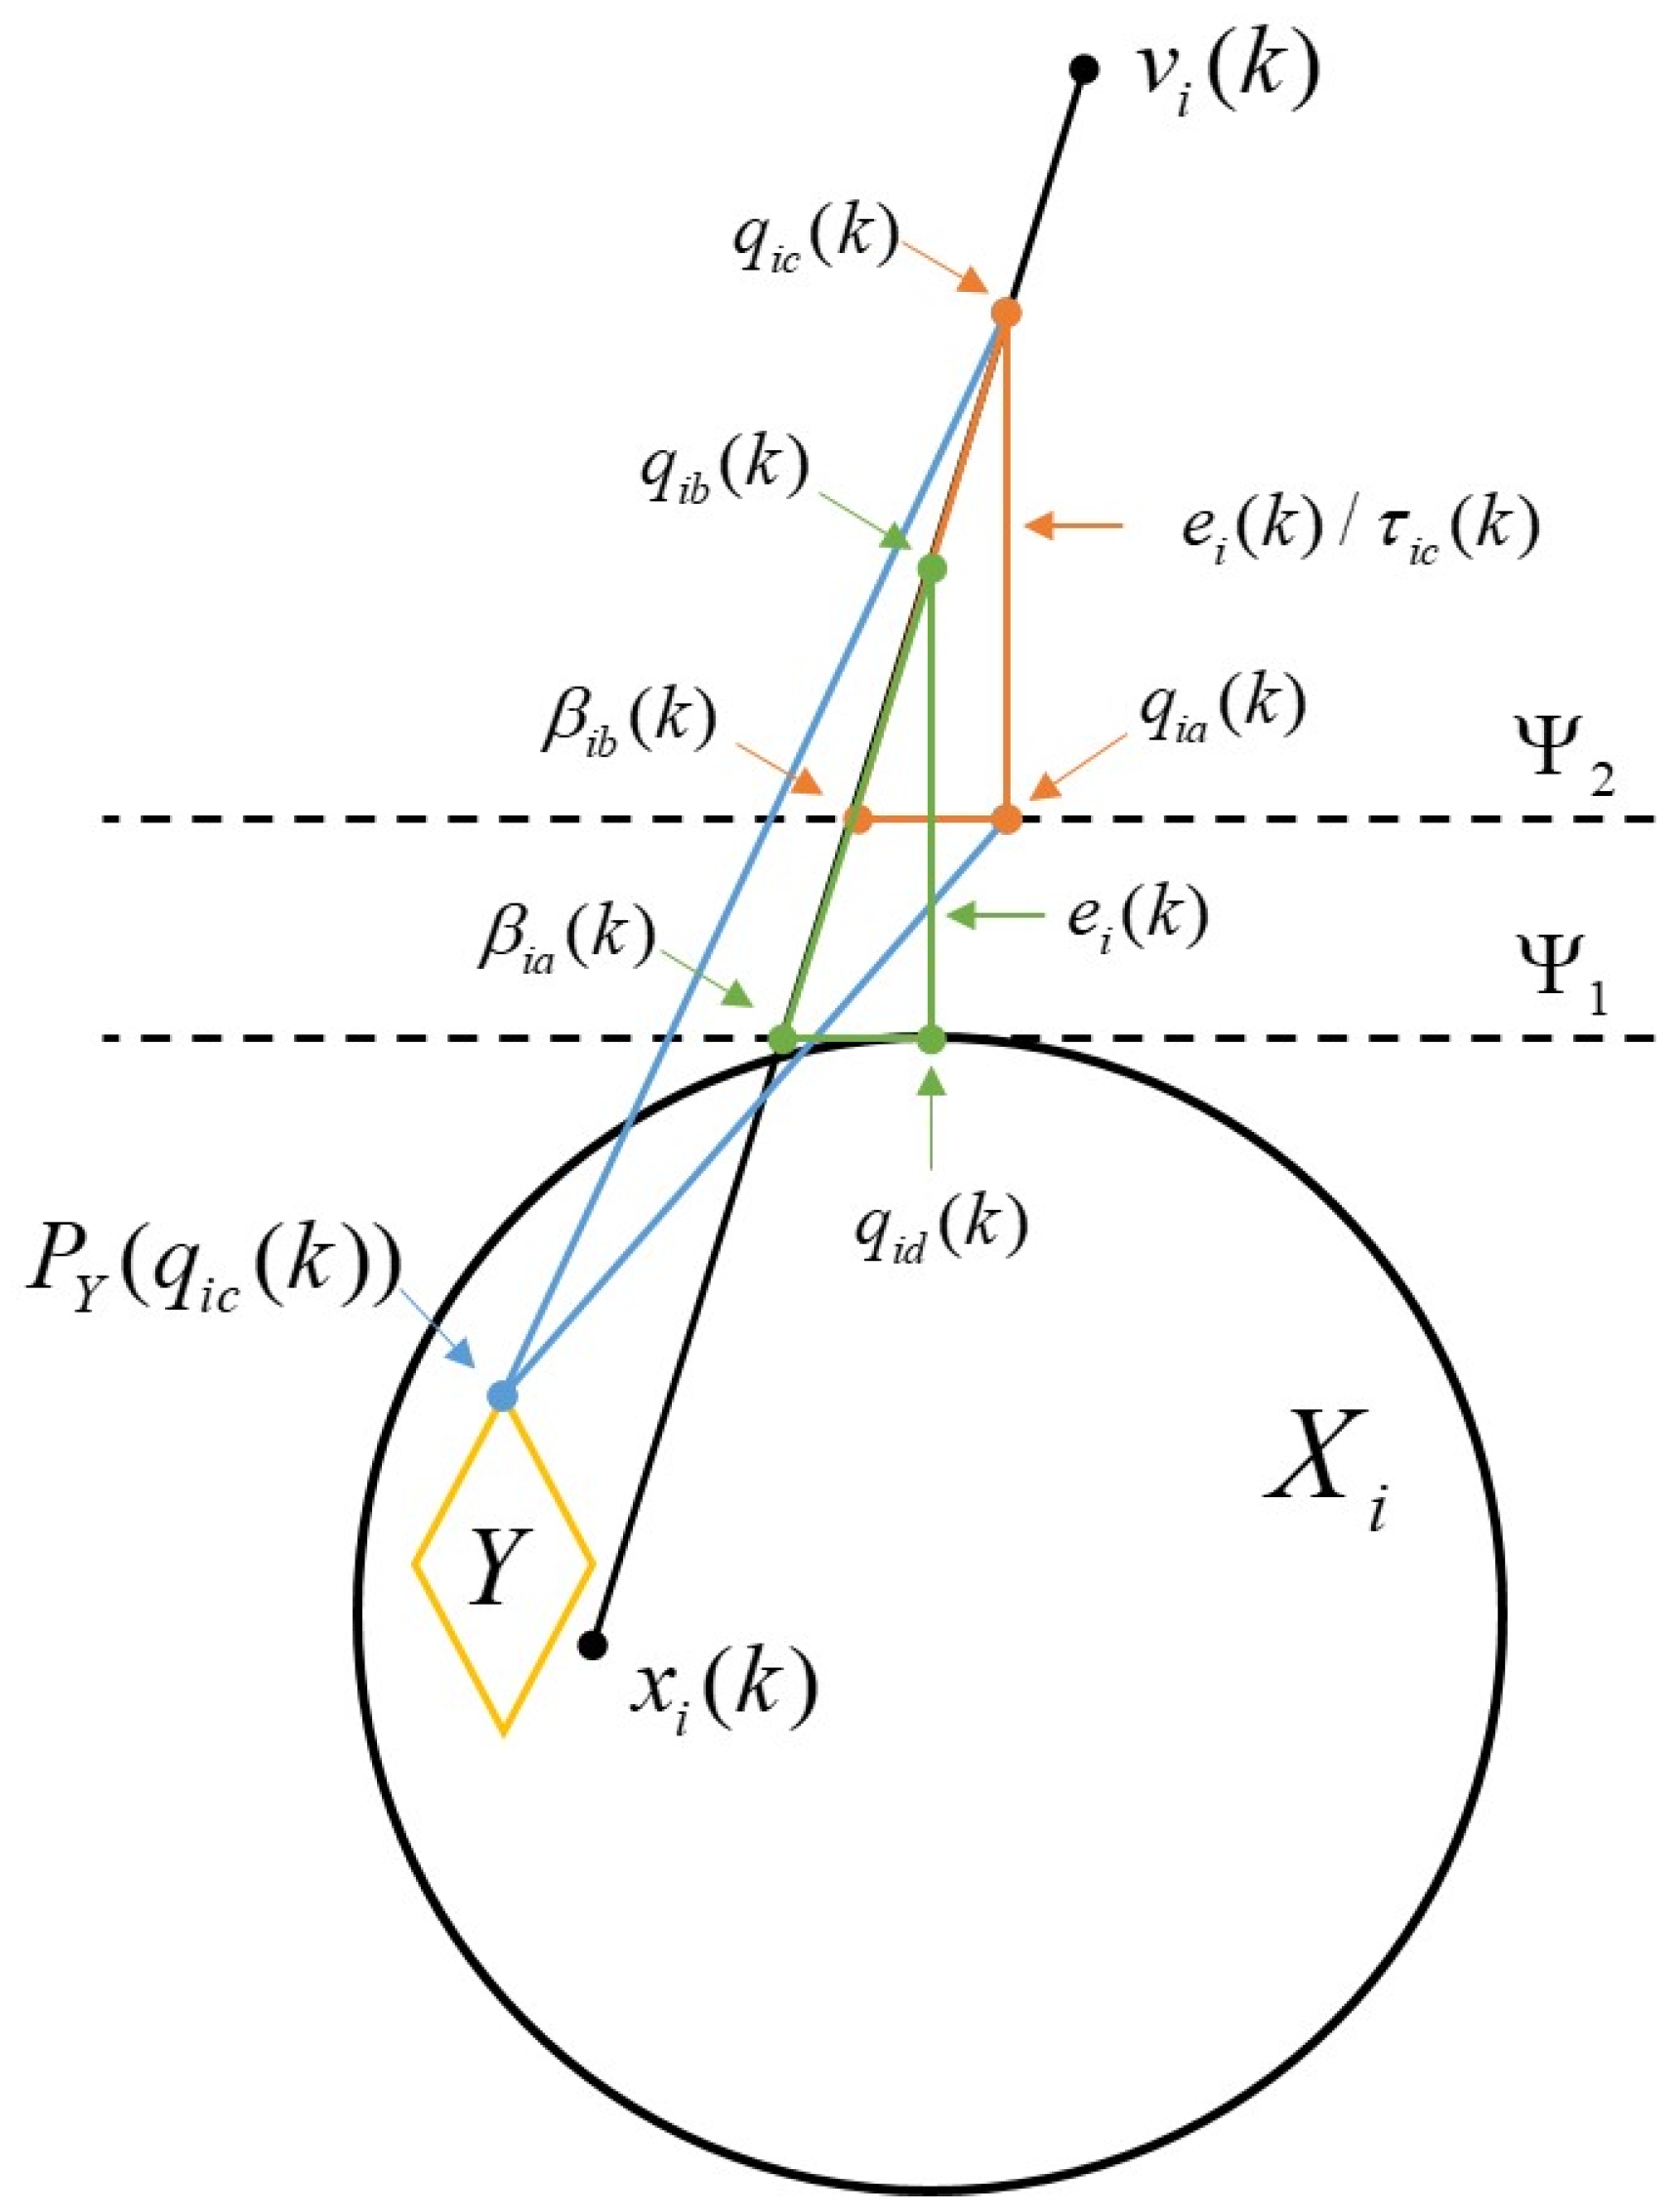
Now, define two hyperplanes and , shown in Figure 2, that is perpendicular to them, and . Meanwhile, it is clear that is perpendicular to the hyperplanes. Then, define and , as shown in Figure 2.
for the constants and .
Figure 2.
Example of similar triangles.
It follows that there exist two similar triangles constituted by points , , and points , , . Now, the characters of similar triangles can be applied.
As shown in Figure 2, define . It follows that . Since the similarity of triangles, it can be obtained that , i.e., . can be obtained in the same way. Moreover, and are at the different sides of . Given all this, it follows that the angle between vectors and is an obtuse angle, which means . Notice Lemma 2 and 4(1), it can be seen that . Above all, it follows that
for . □
3.3. Analysis of Result
In this section, the result of containment control using the given algorithm would be analyzed. First, we design a Lyapunov function.
Let . Design a Lyapunov function as:
Summarizing the above lemma and analysis, it follows that
and
for all .
Next, we analyze the convergence of containment control problem under the given algorithm in the time interval .
Case A. Assuming that there is an agent that can get information from one of the static leaders at . Clearly, and . Note that
and
where .
Moreover, there is
where .
Case B. Suppose that there exists an agent that satisfies at time . It can be deduced from Lemmas 4 and 5 that
where .
Moreover, it follows that
Then, after recursive calculations, we can obtain and where .
Case C. Suppose that there exist 2 agents and that satisfy for some constant and for some constant at time , which means agent can receive information from agent at . It follows that
where .
From , it can be obtained that
Hence, by using Lemma 5, it follows that
where .
Theorem 1.
Based on Assumptions 1–4, applying constrained control input algorithm (2) to System (1), all followers are driven into the convex hull spanned by leaders, i.e., for .
Proof of Theorem 1.
As shown in Assumption 2, it can always find one or more follower that can receive information from one of the static leaders directly in every time interval , which guarantees the condition of Case A. That is, and hold, where and ; then, consider Case B, it follows that and works for and all . It is clear that agent which could get information from agent or one of the static leaders at exists. Hence, by using the calculation of Cases A, B, and C, it could be obtained that and for and all . Recall that the constants , , , and are only affected by constants , , , , , and topologies in the time interval. Therefore, it can certainly find a constant satisfying , where . Given all this, holds. To summarize all the calculations, we have for . □
4. A Numerical Example
4.1. Simulation Parament Configuration
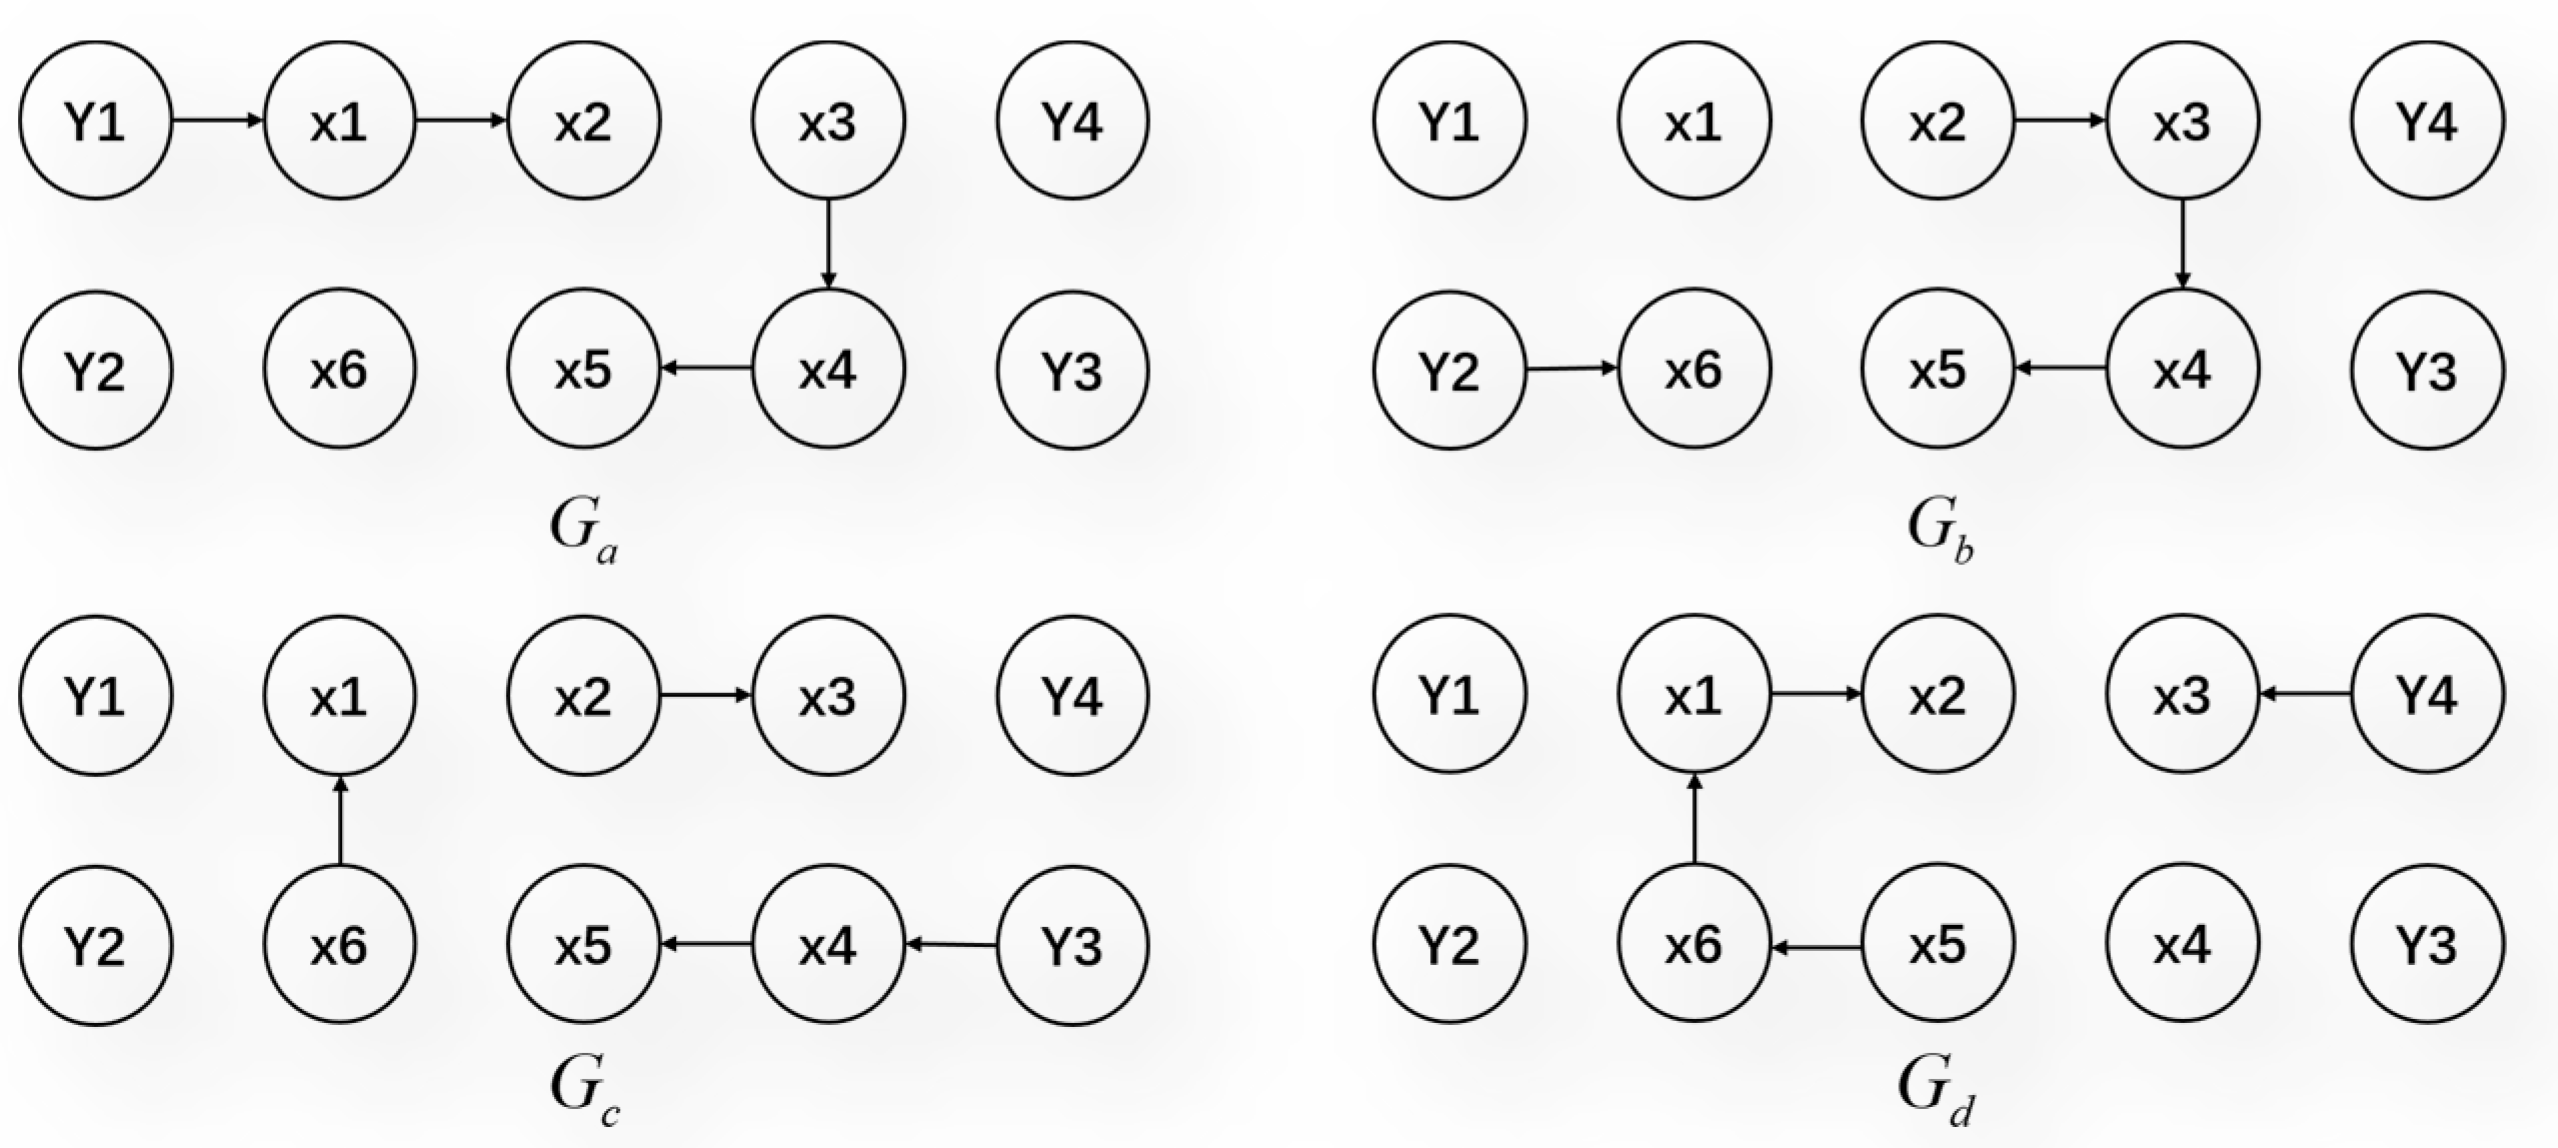
Give a multiagent system composed of 6 followers and 4 leaders. The graphs of switching topologies are shown in Figure 3. The switching step of the system is 0.5 s and the sequence of the graphs is , , , . The weights of all edges . The parameters are and for and the sampling time is . The control input constraint set is . The position constraint sets of the followers are and . For followers, the initial states of position are and the initial states of velocity states are . For leaders, the initial states of position is .
Figure 3.
Switching graphs.
4.2. Simulation Result
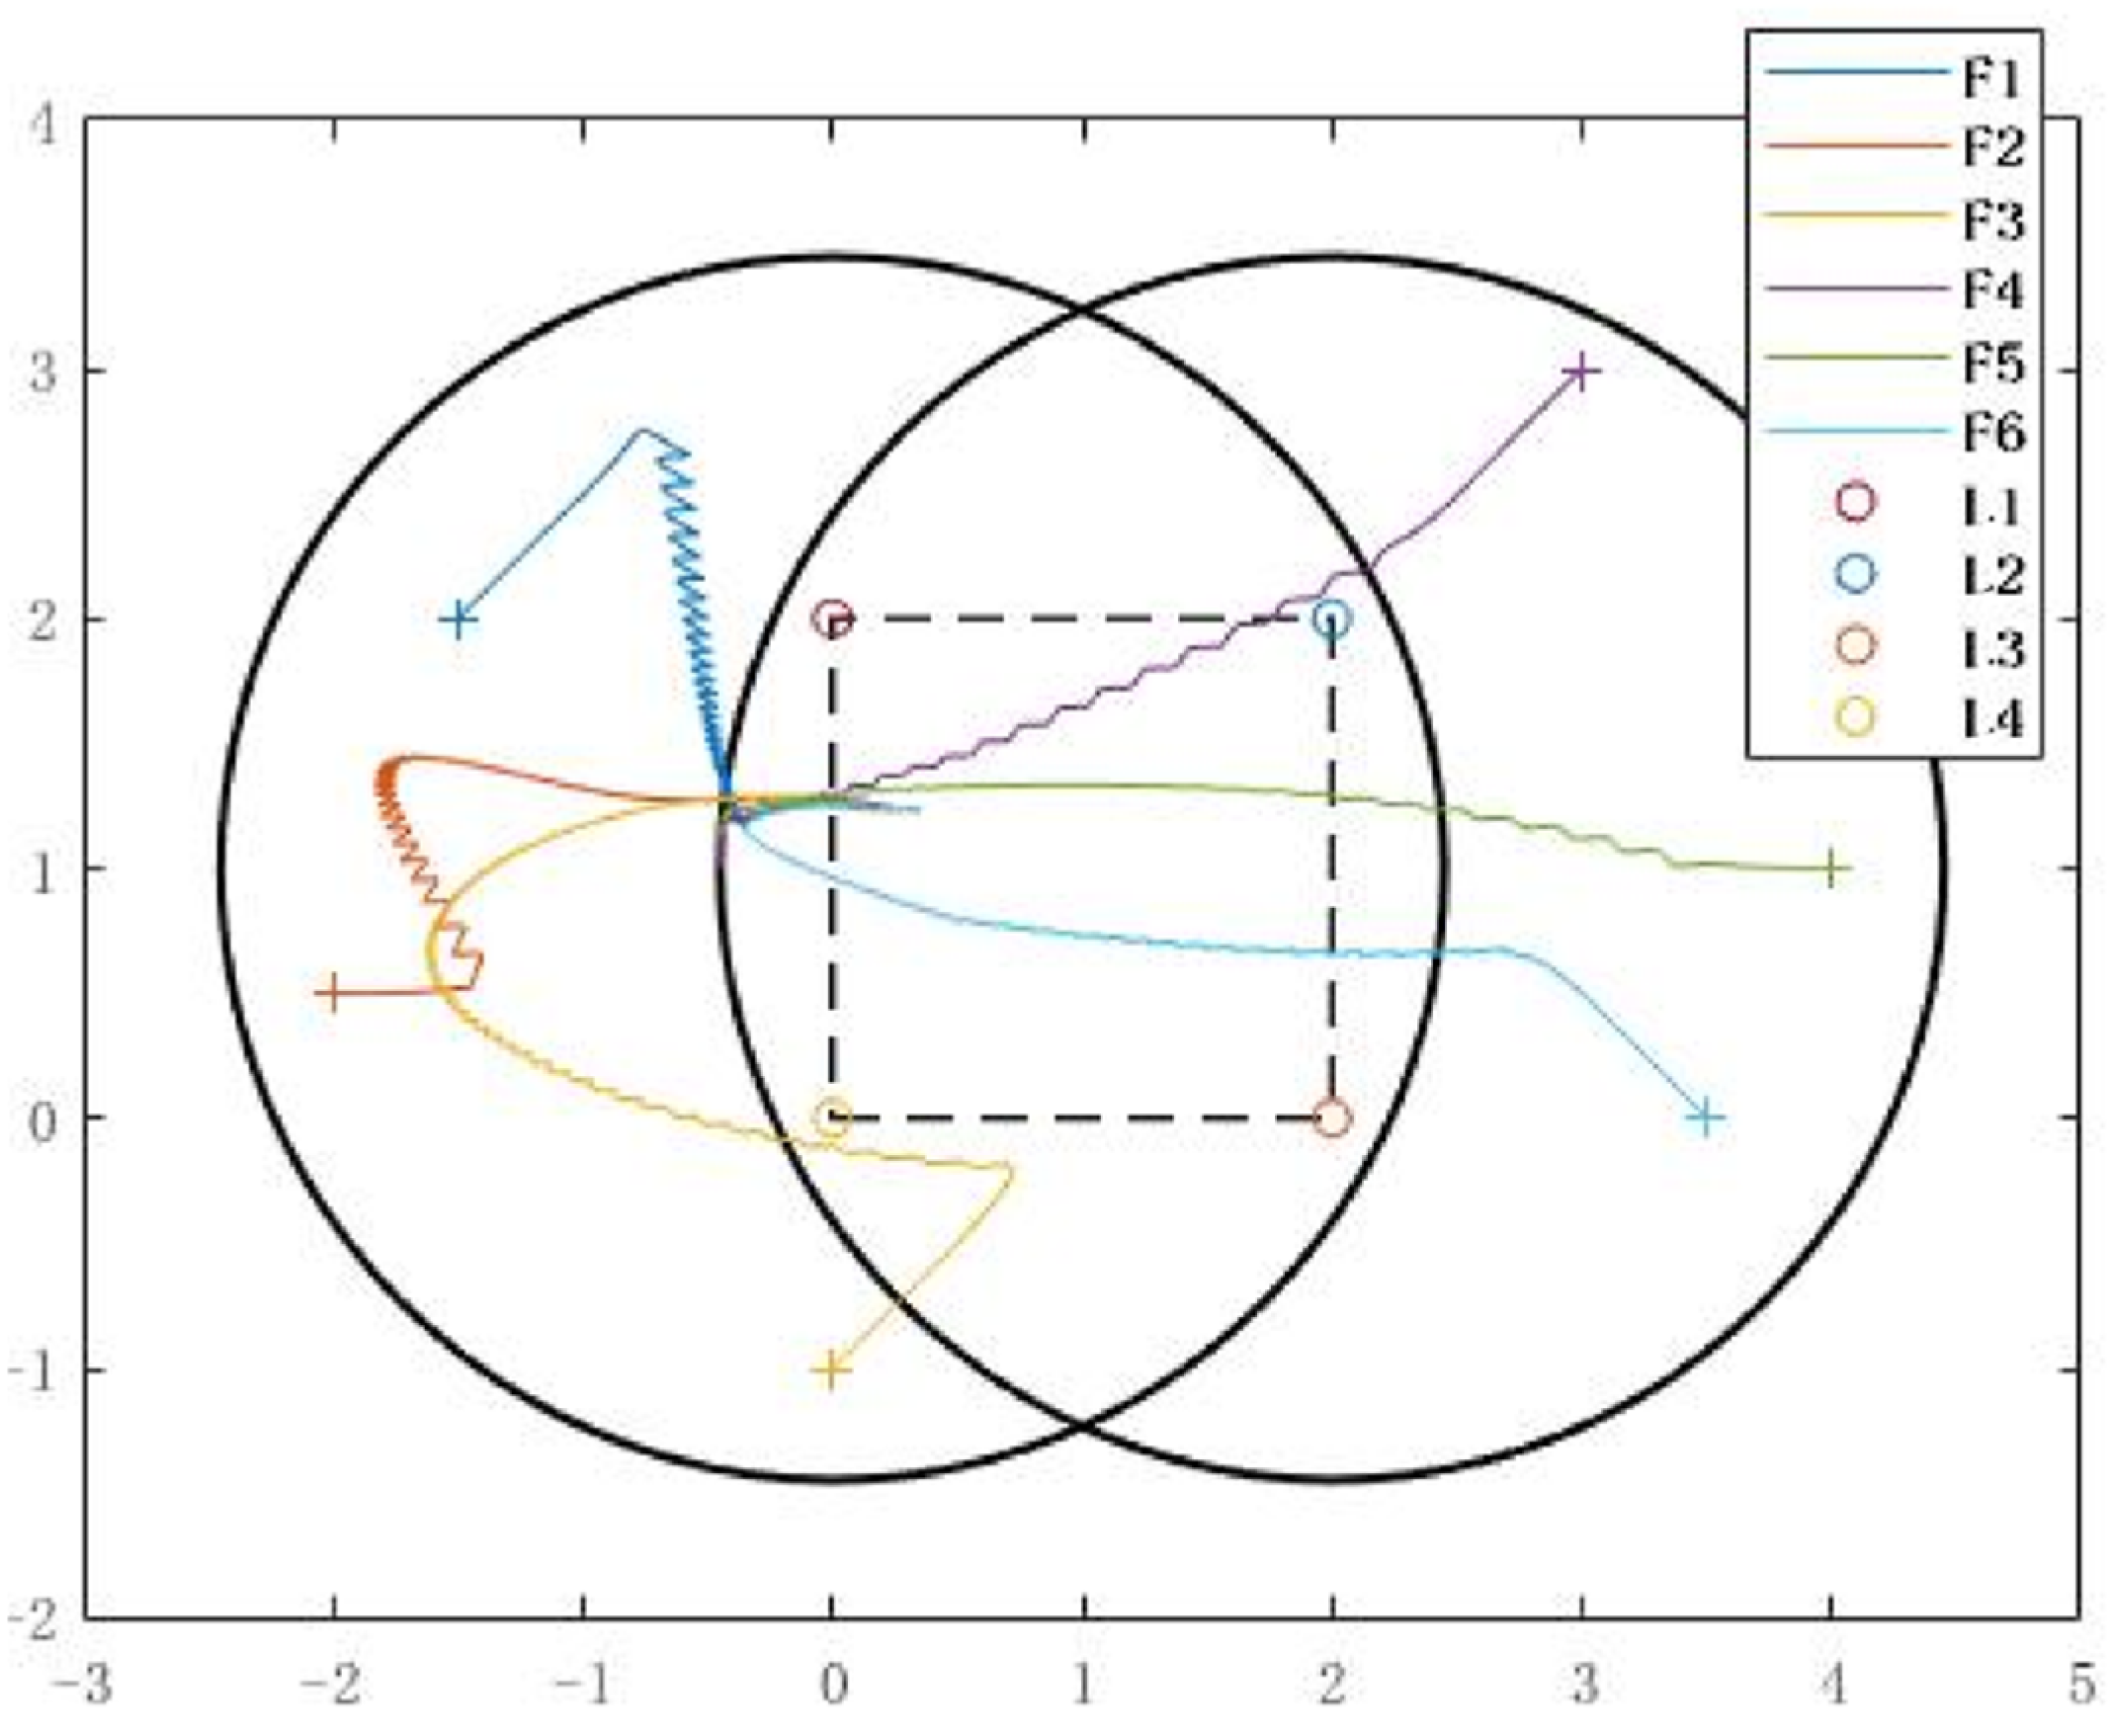
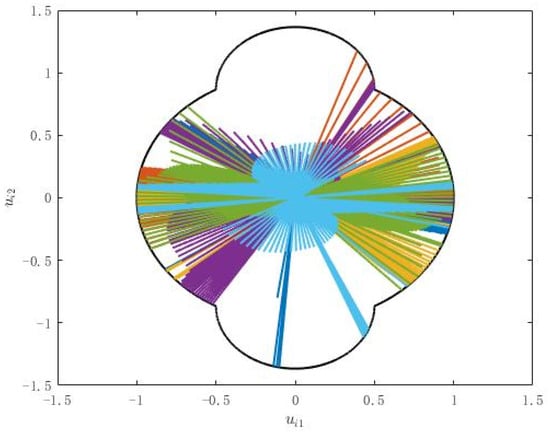
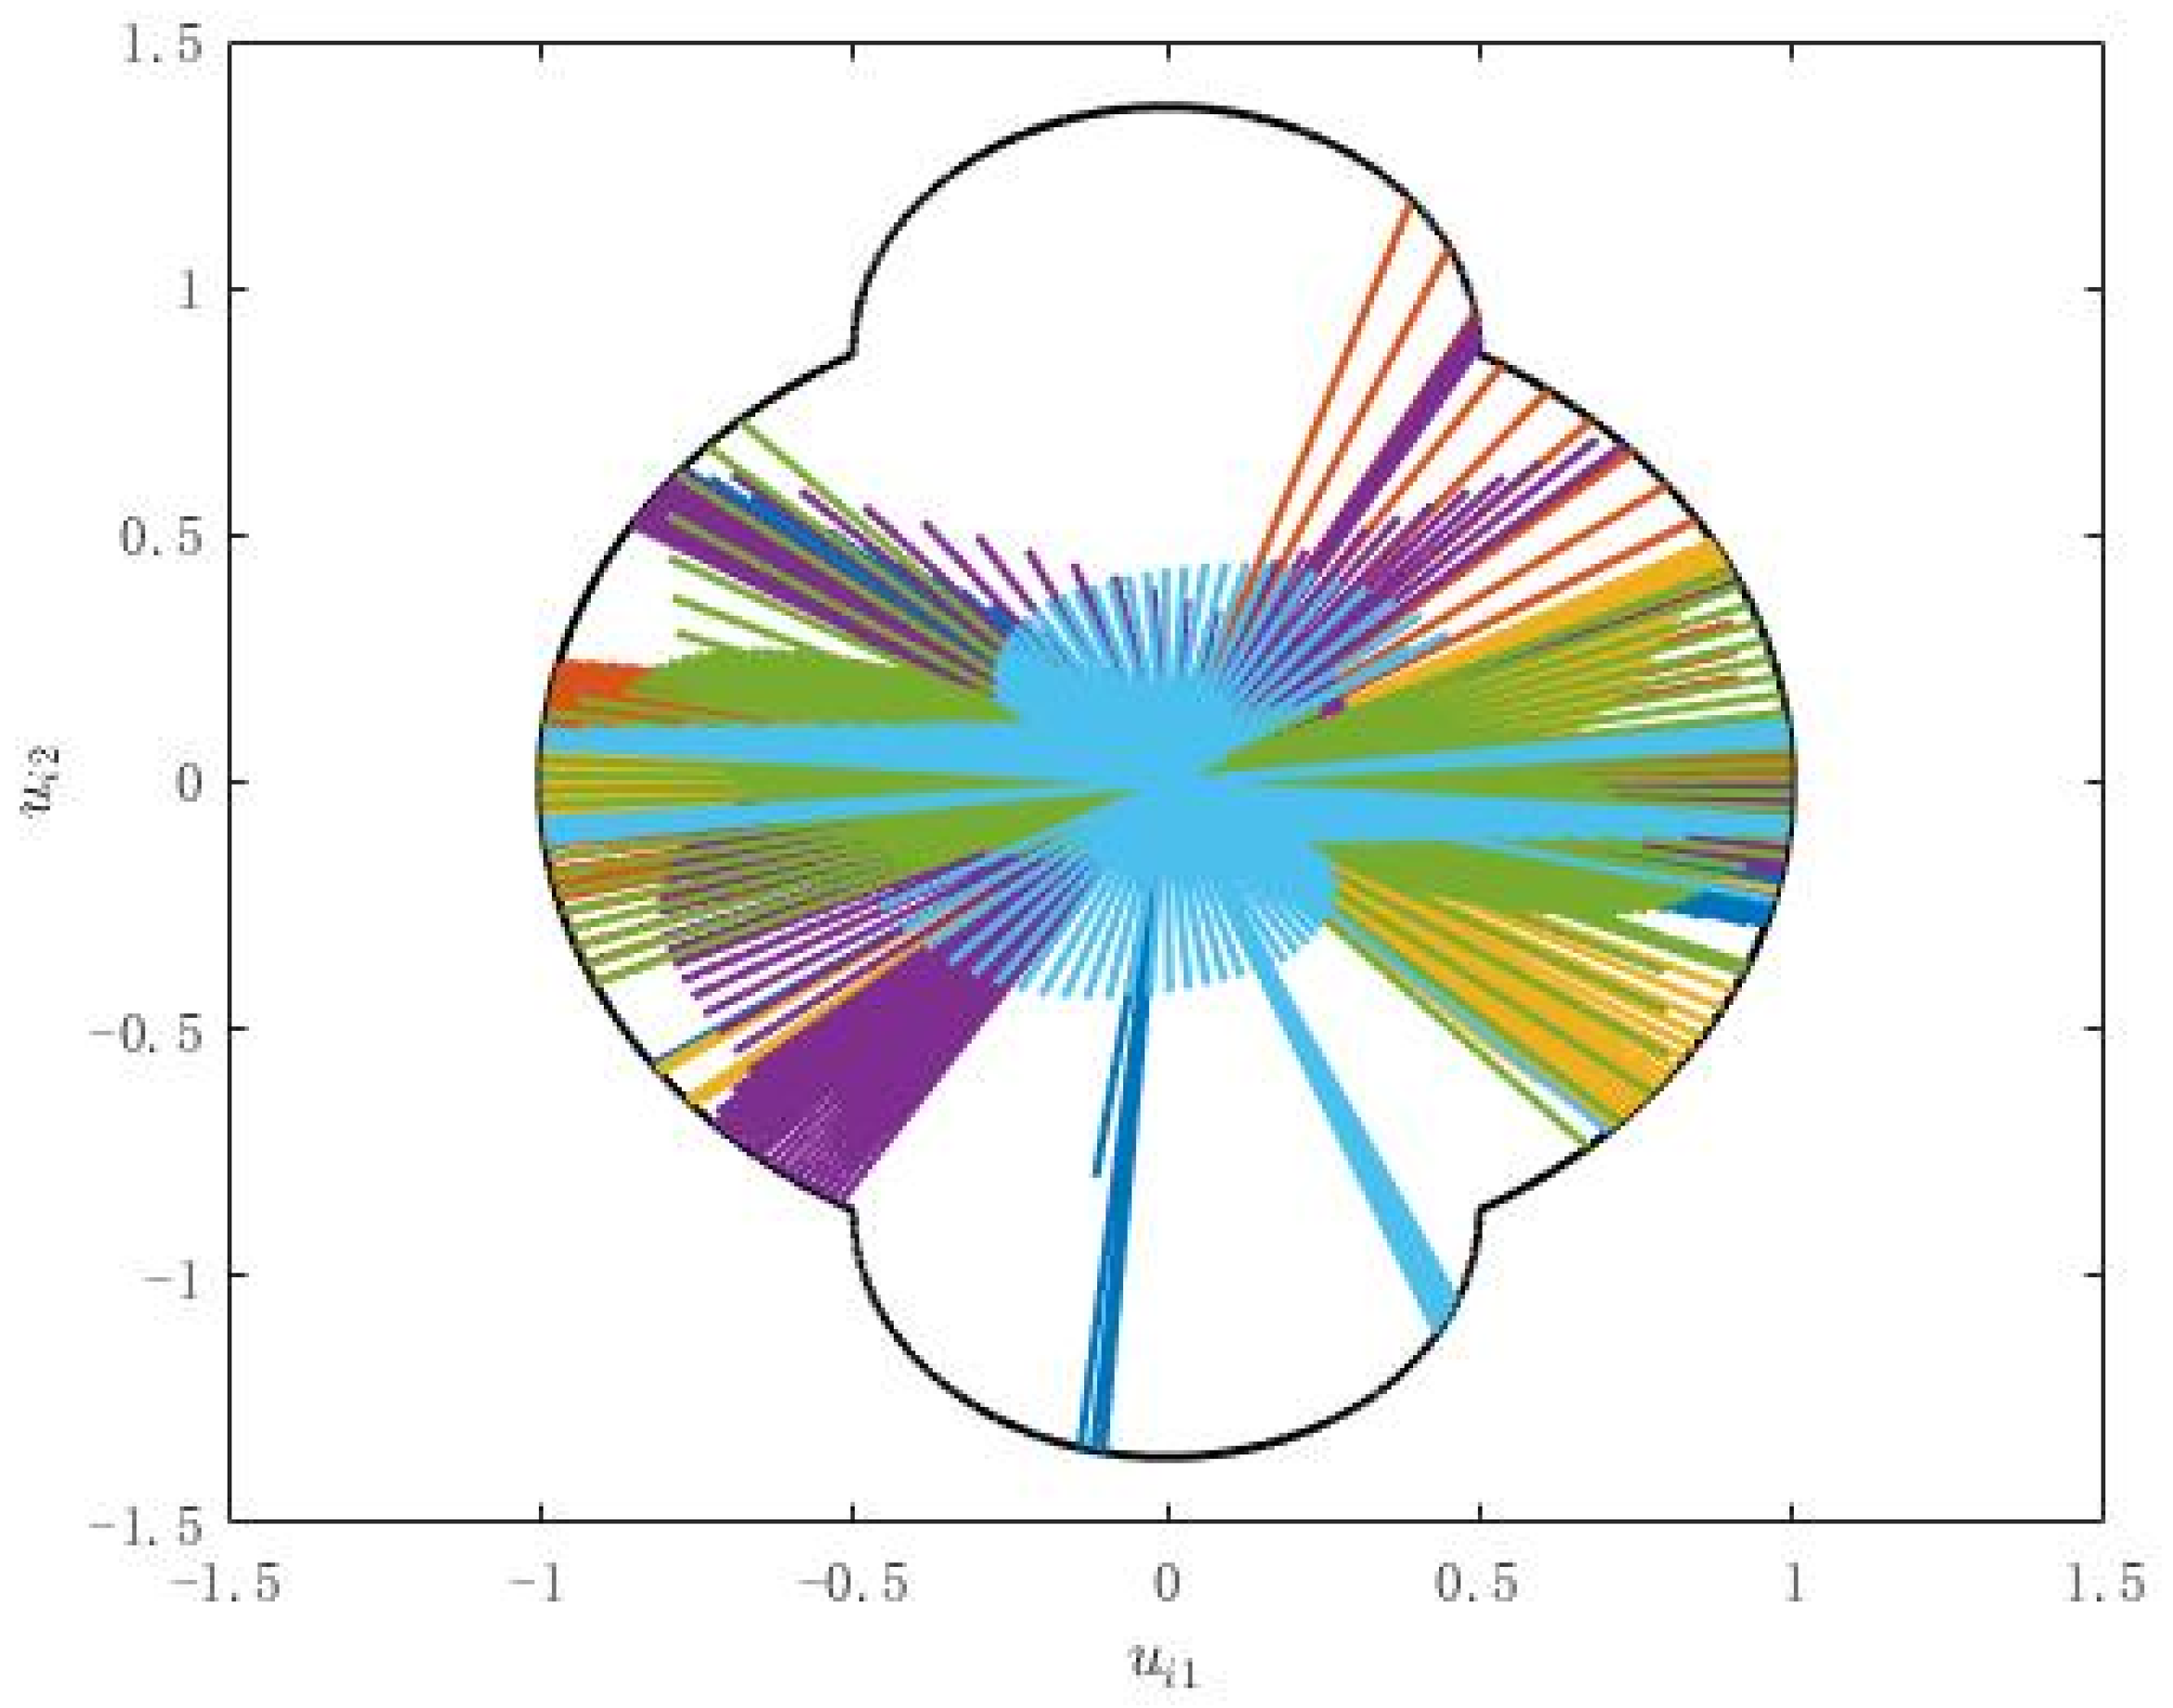
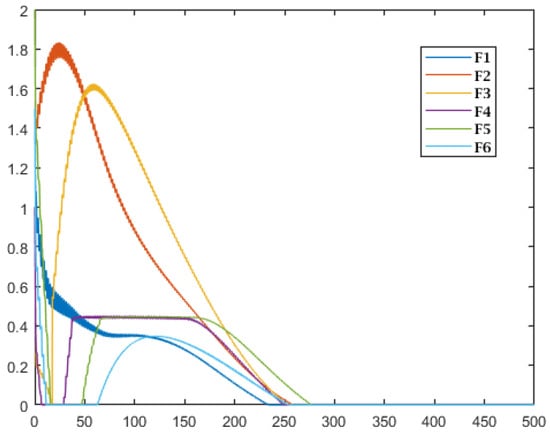
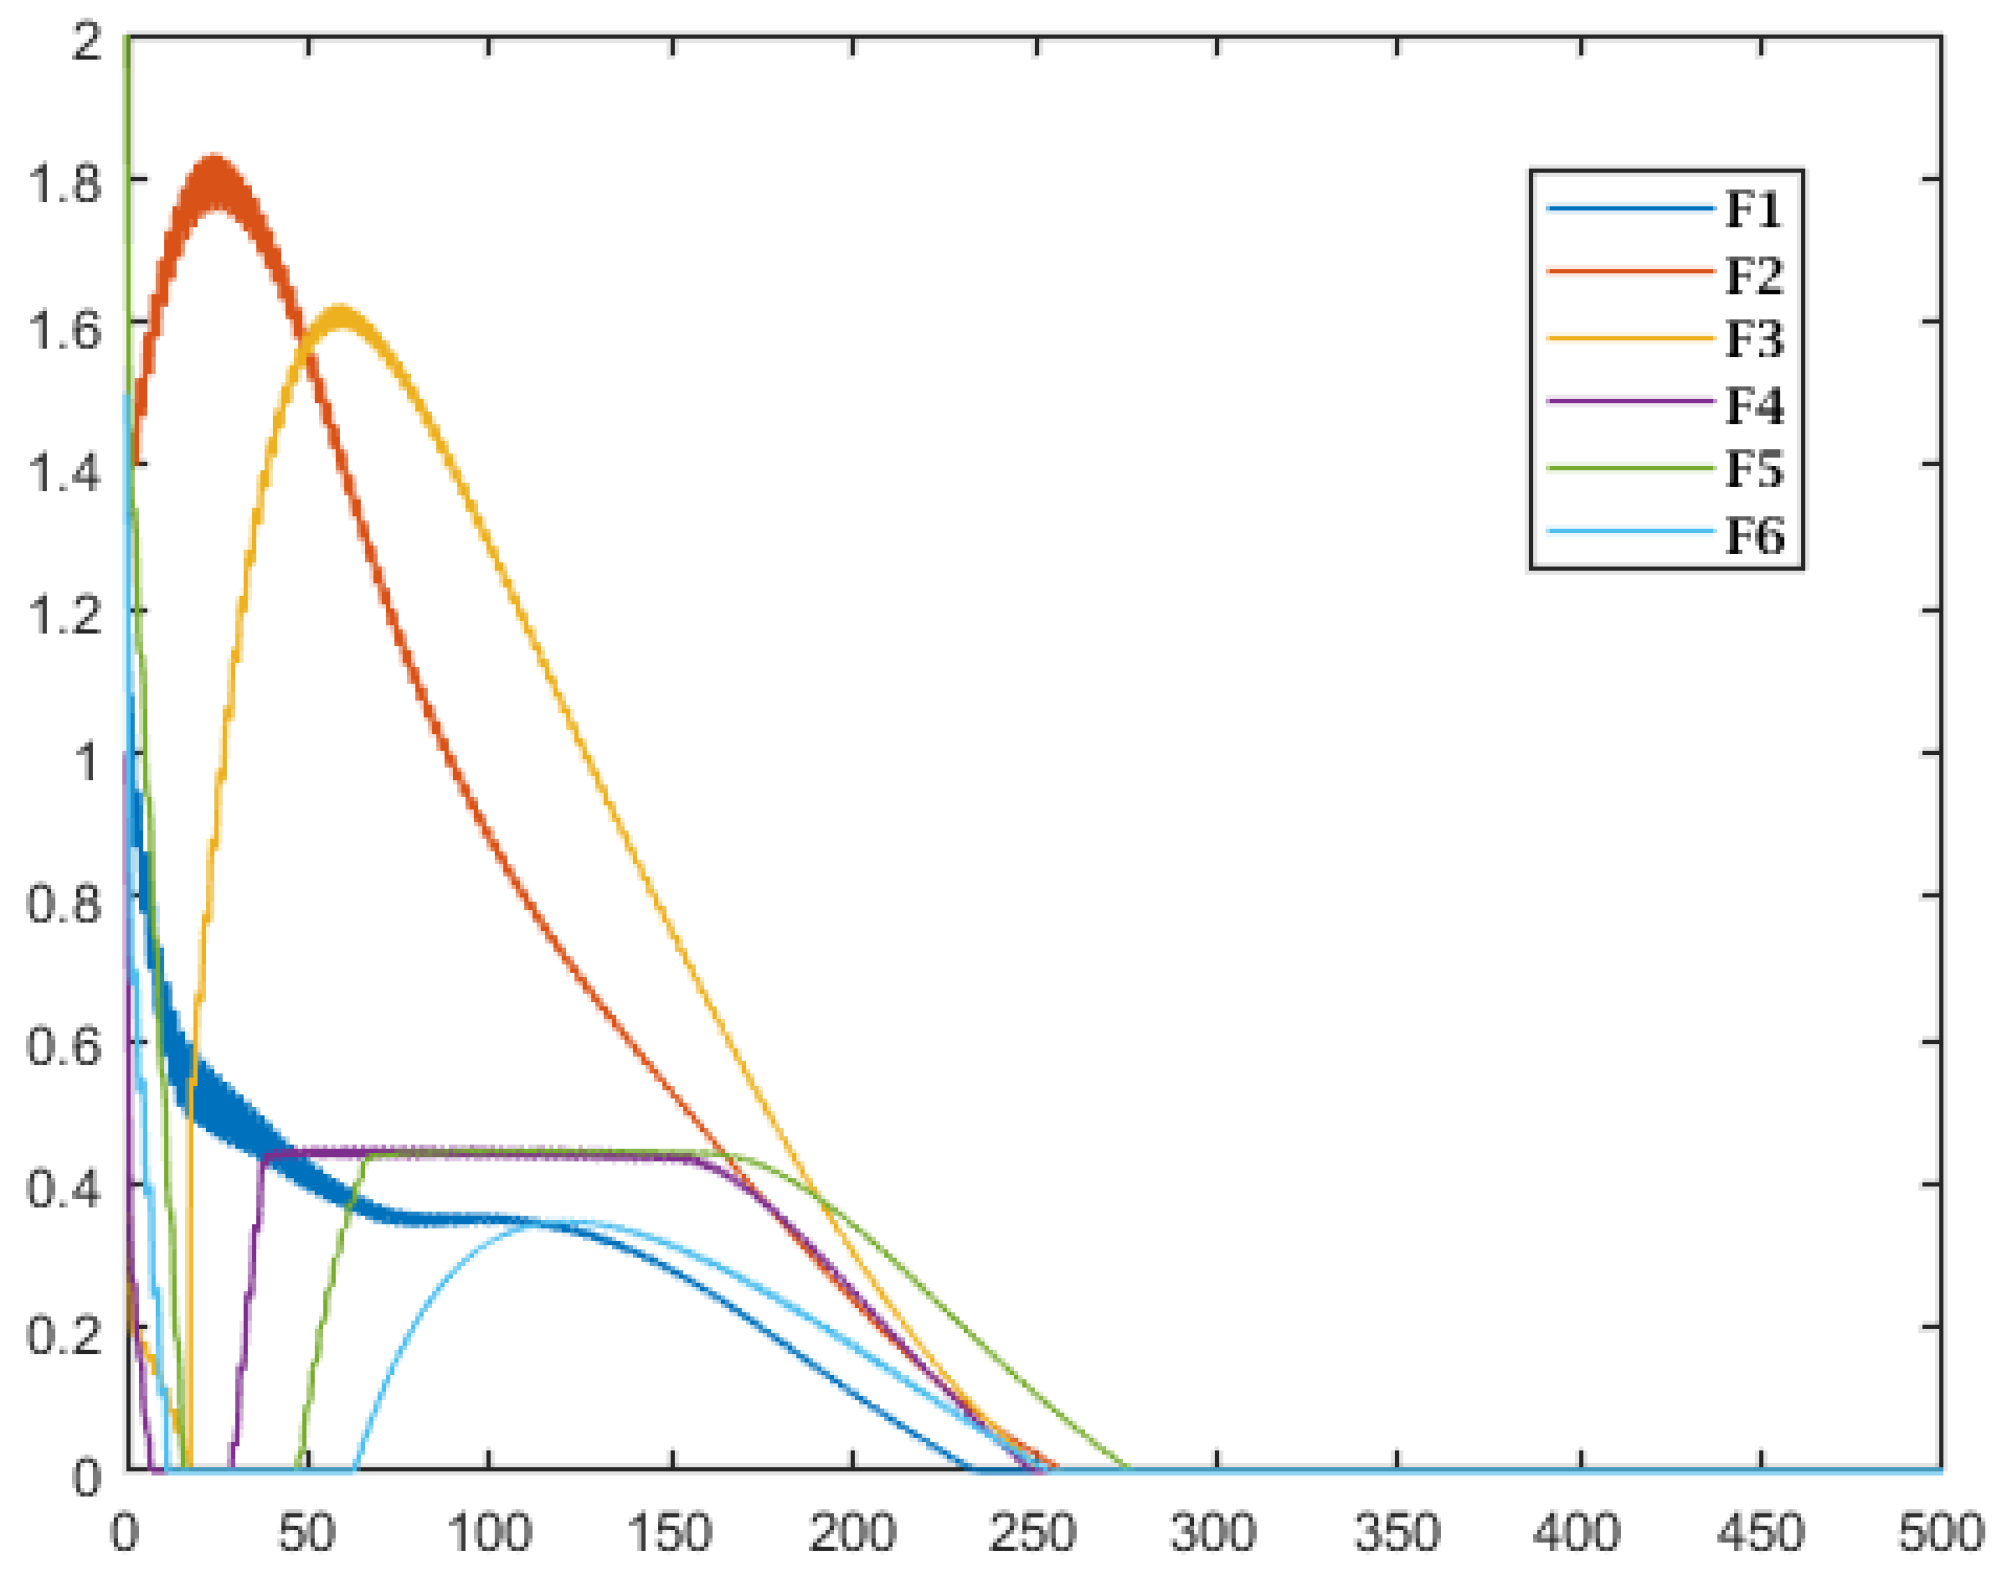
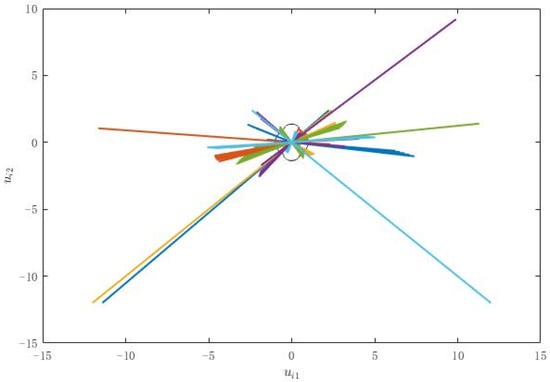
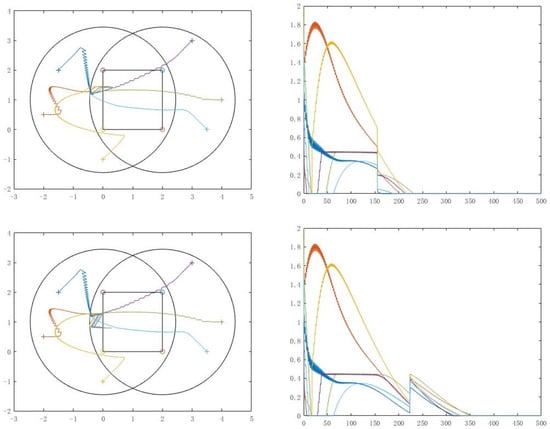
The convex hull is spanned by static points, as illustrated in Figure 4. Figure 5 shows the control input of followers. The containment errors of followers are shown in Figure 6.
Figure 4.
Position states of all agents.
Figure 5.
Control input of followers.
Figure 6.
Containment errors of followers.
The switching graphs are illustrated in Figure 3 which satisfy the assumption that each follower could get information from at least one leader directly or indirectly in every time interval. In Figure 4, Followers 1, 2, and 3 stay in the left circle which illustrates the constraint of position, while Followers 4, 5, and 6 stay in the right circle. The convex region spread by the 4 leaders is the target region. Figure 5 gives the constraints of control input that is a nonconvex hull. It shows the containment errors of followers by using the distance form every follower to the target region in Figure 6.
4.3. Simulation Comparison
In this section, we provide some simulation comparison results.
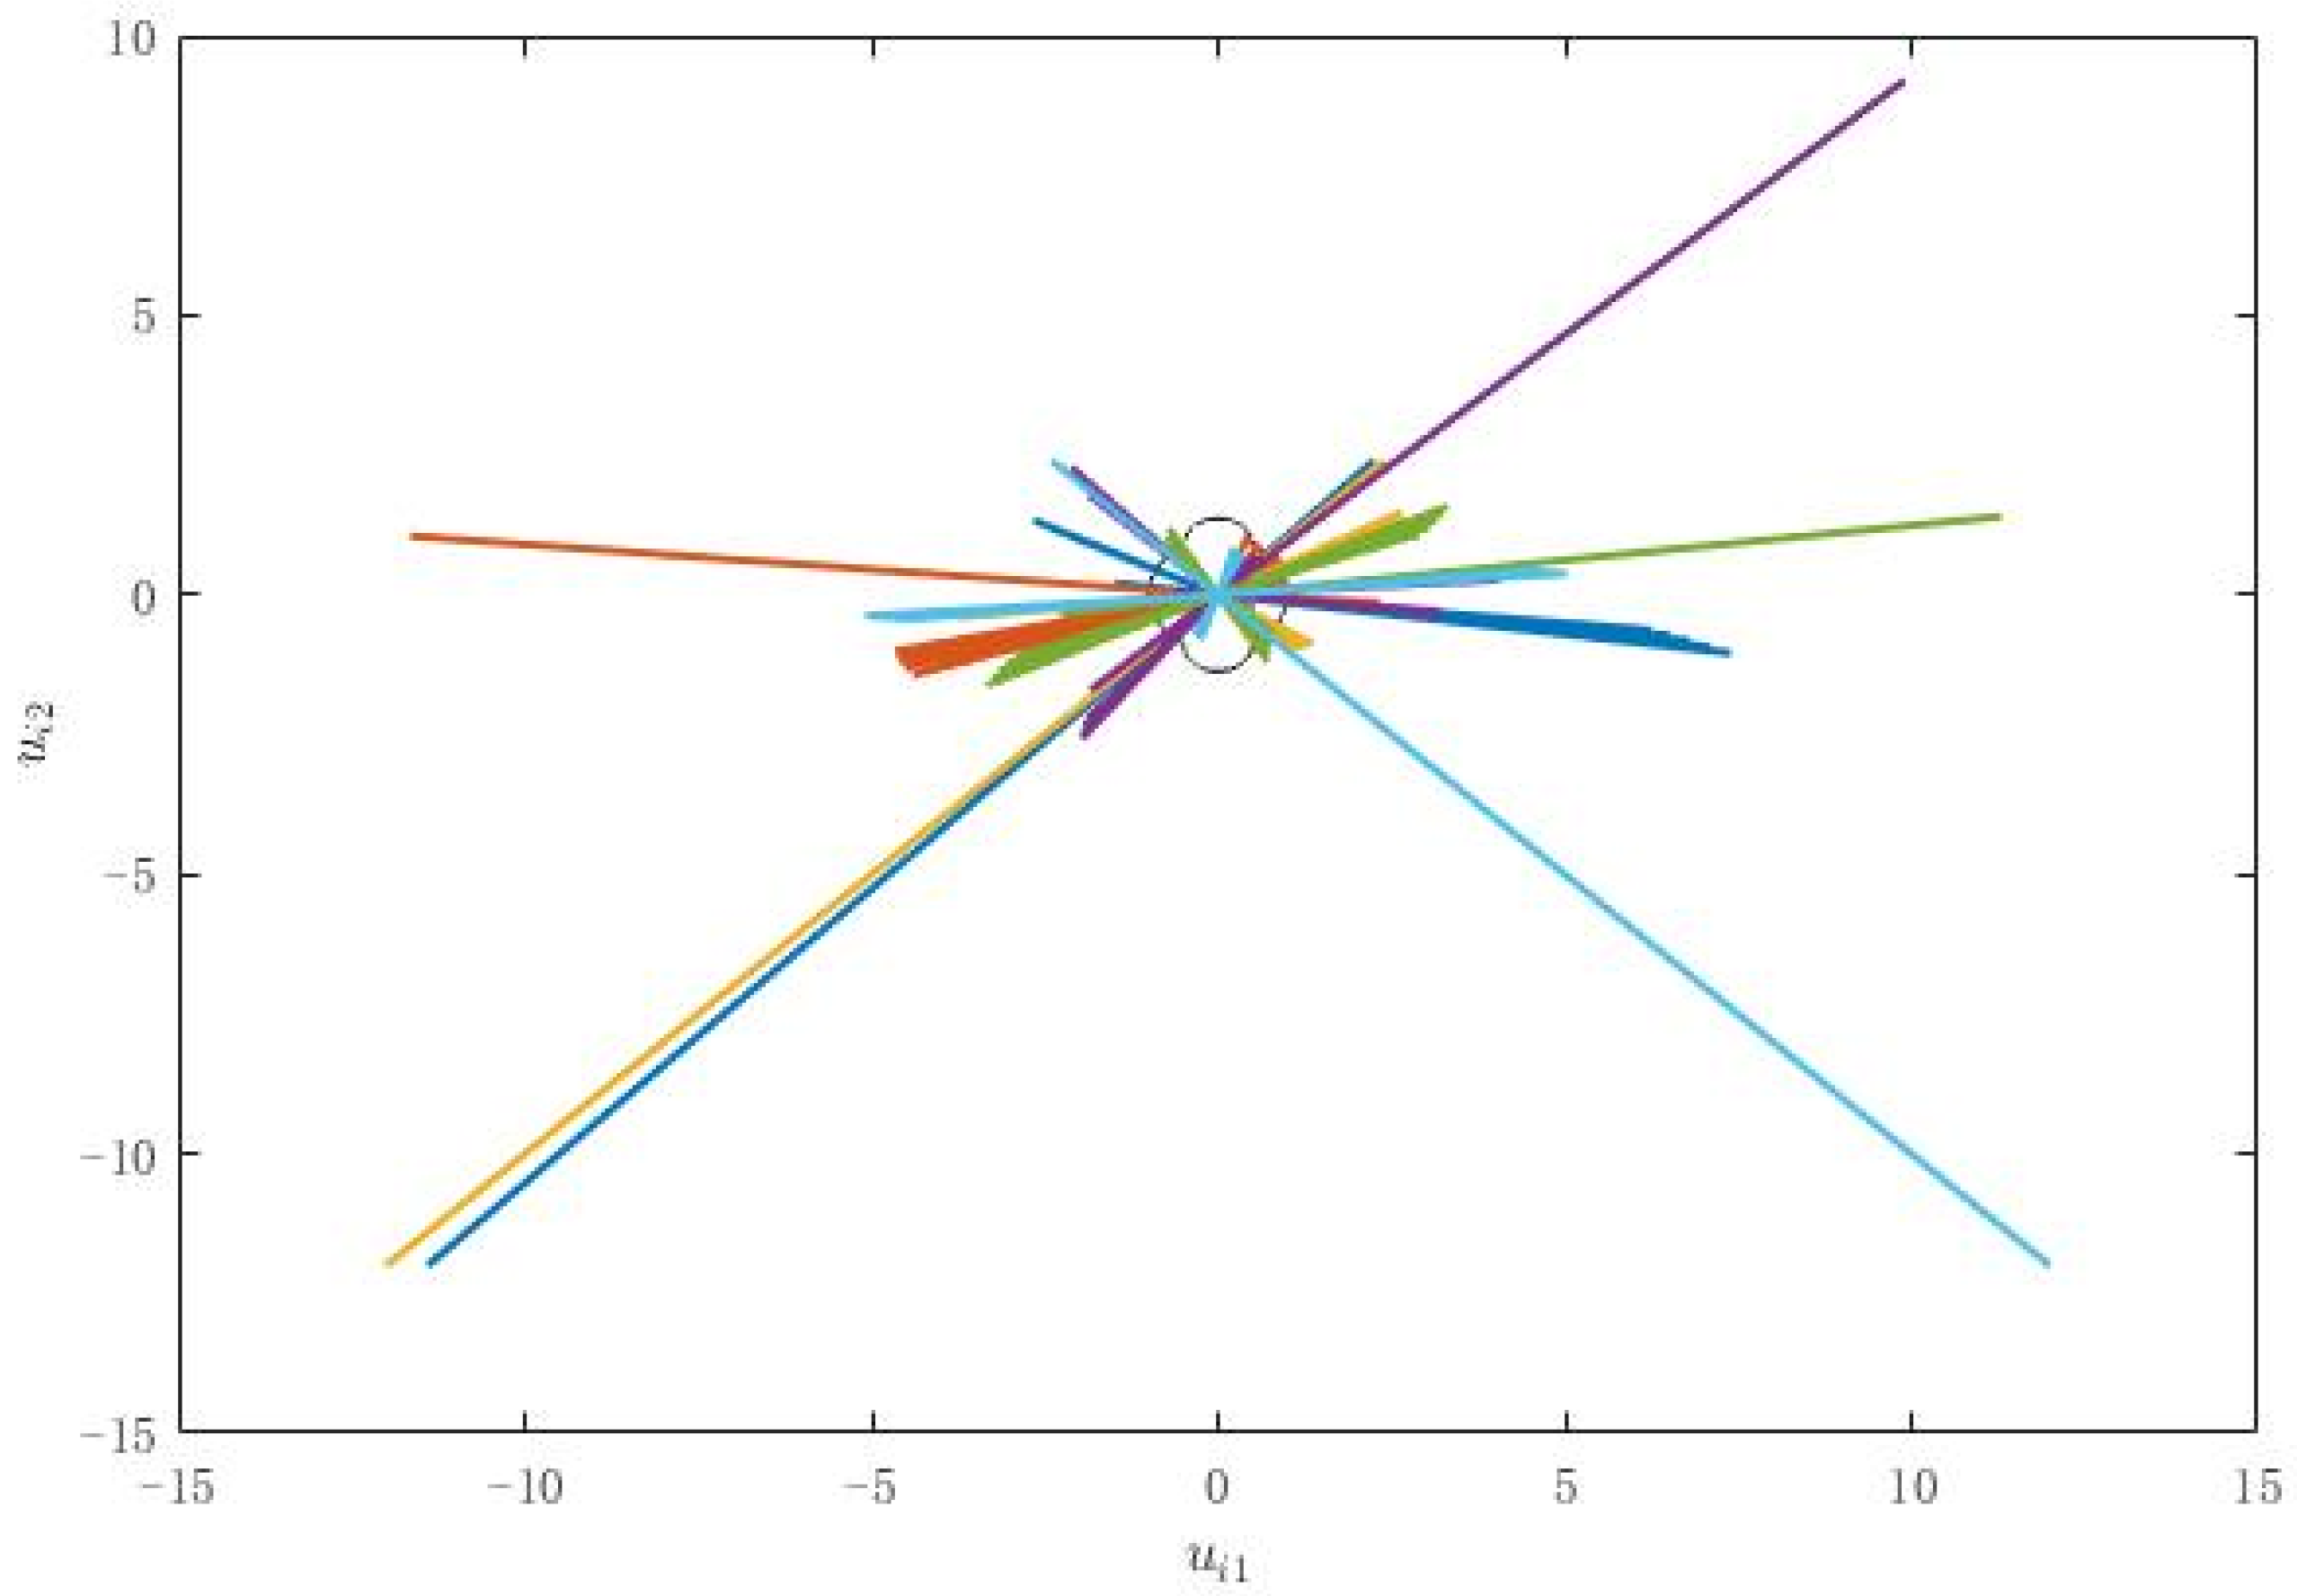
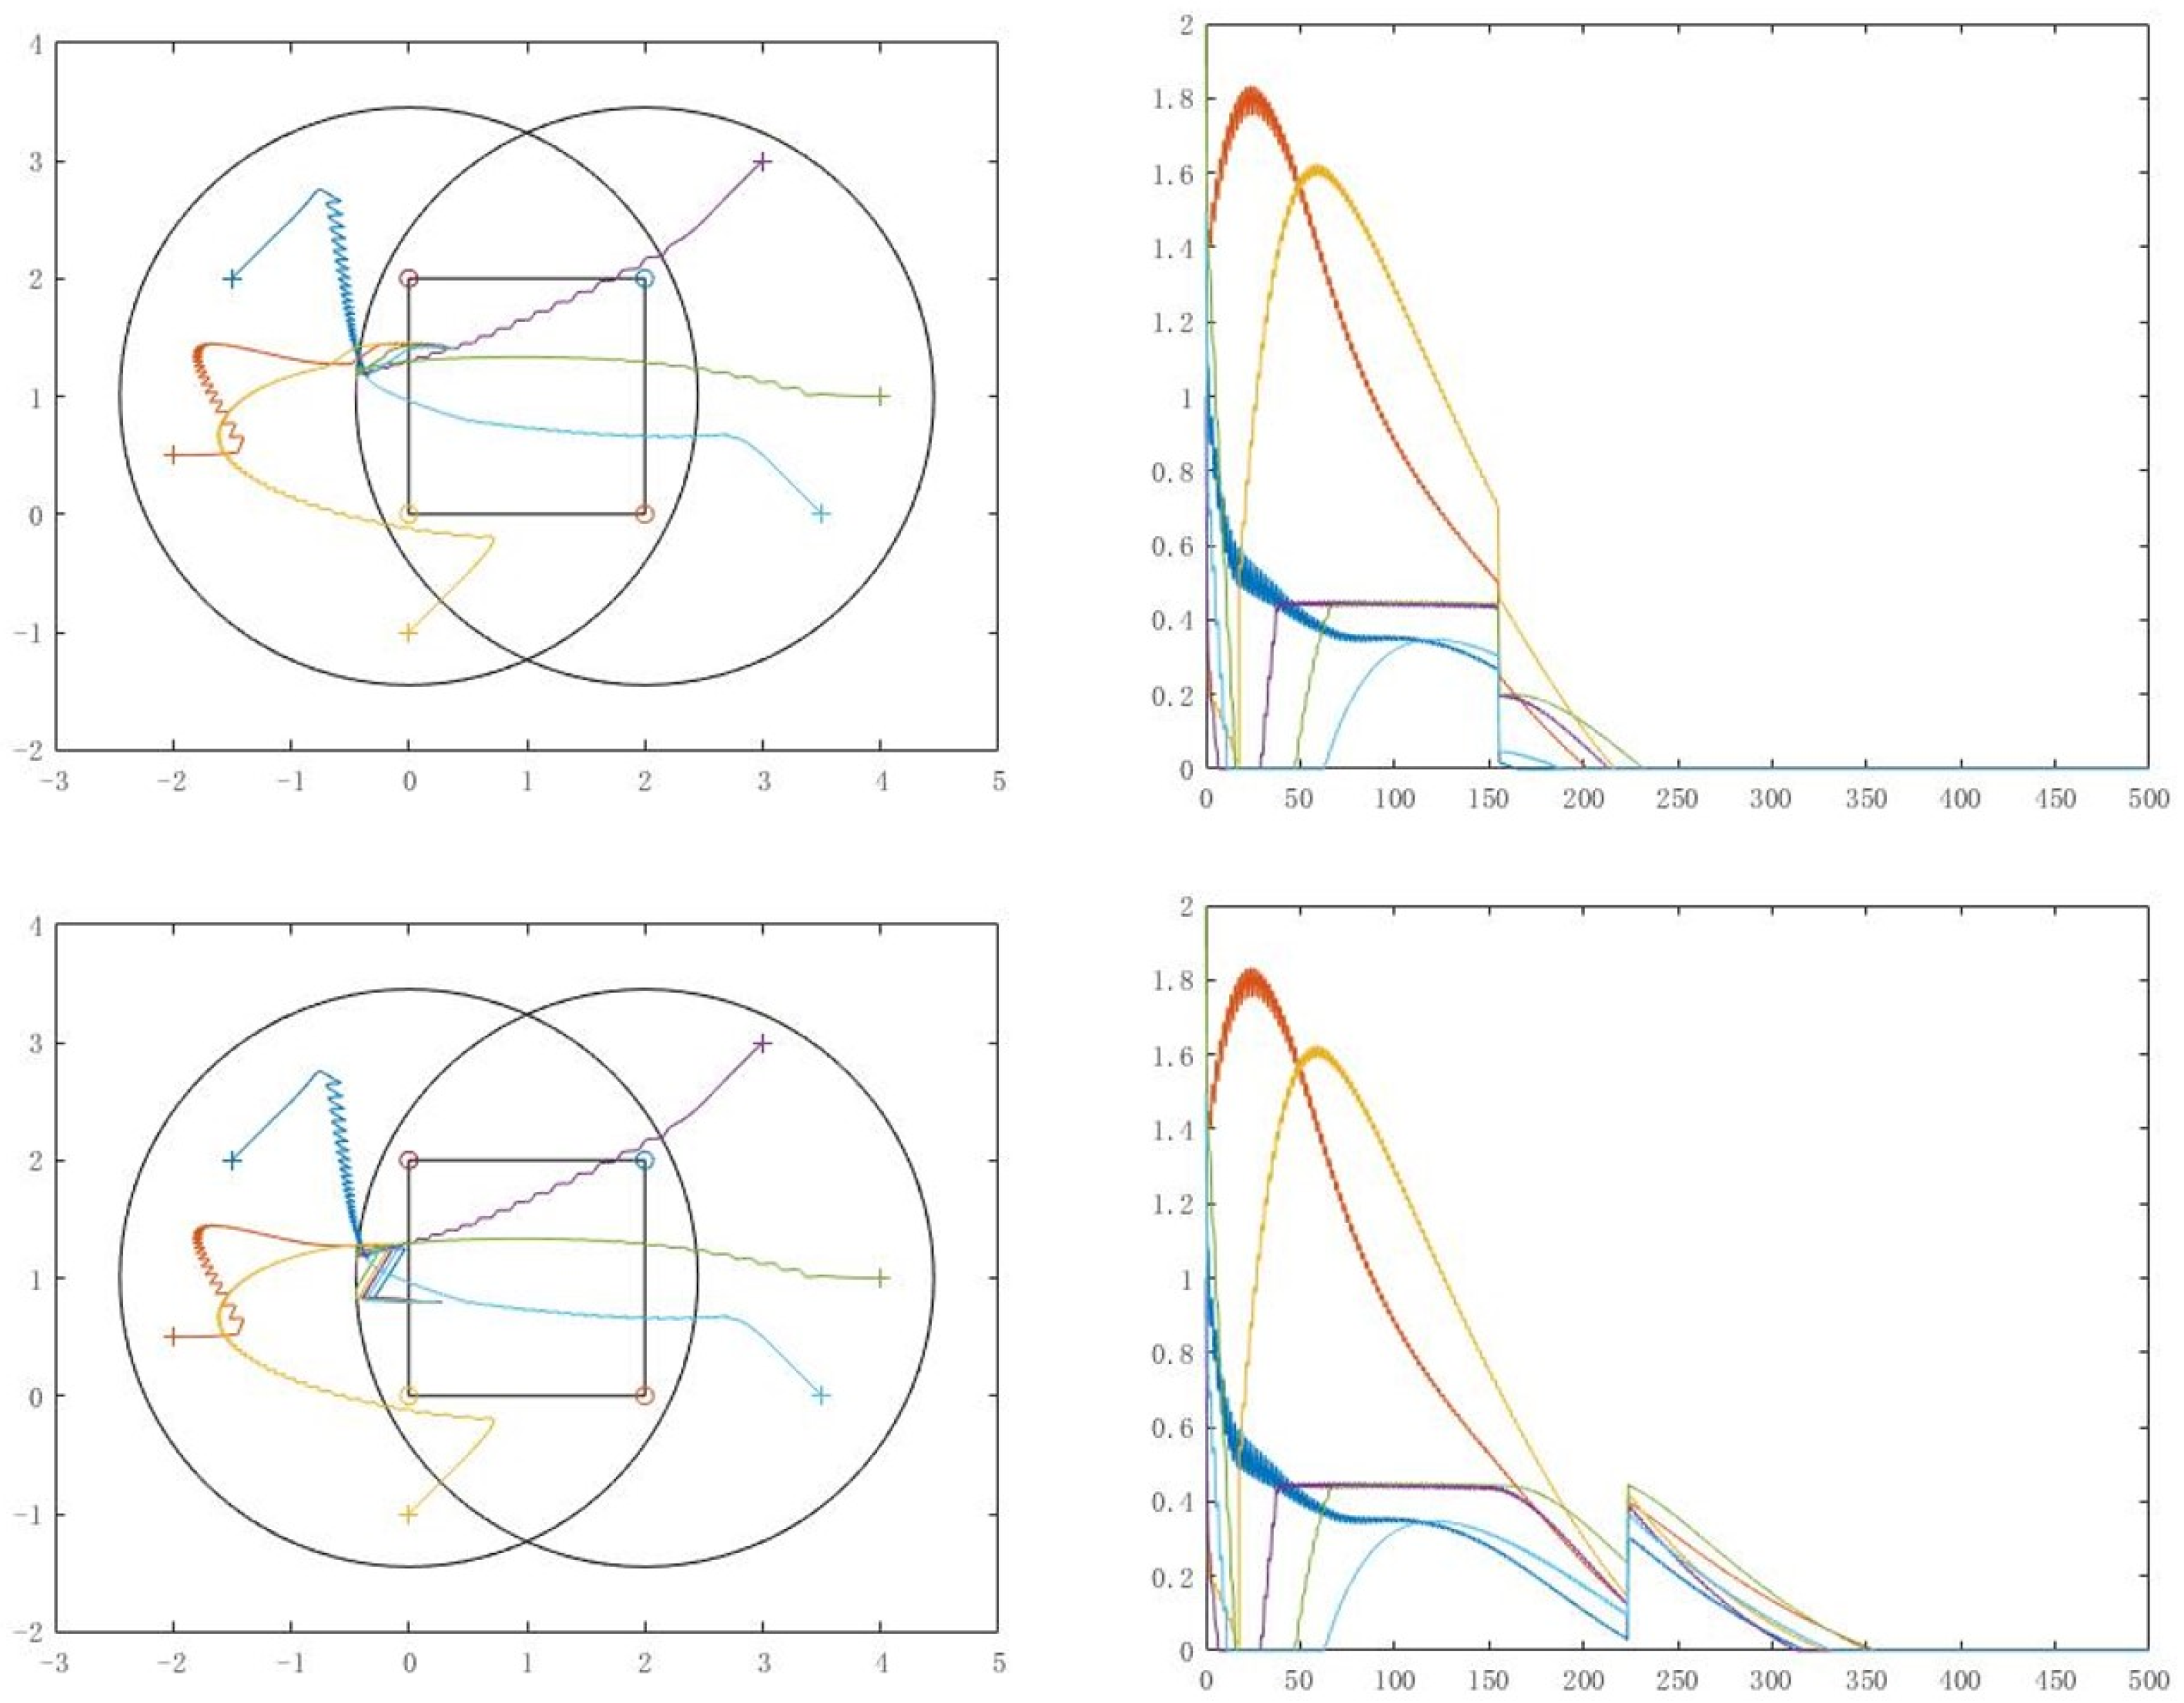
As compared with Figure 5, Figure 7 shows the control input without constraints. It is clear that our algorithm could be more practical in reality. In Figure 8, we can see that the algorithm can still achieve containment control when a sudden interference happens, which means the algorithm has stability to some extent.
Figure 7.
Control input without constraints.
Figure 8.
Position states and containment errors with interference.
5. Conclusions
In the above work, containment control for a multiagent system with nonconvex control input and position constraints was discussed. To solve the problem, a nonlinear algorithm with projection operator for followers was proposed. After the analysis of the distance from every follower to the convex hull spanned by static leaders, it is found that all followers could be driven into the convex hull formed by leaders and the position states of followers remain in the constraint set. Finally, a numerical example is given to guarantee the theoretical results.
Under analysis of the algorithm and simulation results, our work has the following advantages:
- (1)
- The projection operator we introduced can ensure the control input of every follower to lie in a nonconvex set which is useful in practice. It has apparent superiority as compared with other algorithms which can be seen in the simulation.
- (2)
- With the existence of constraints both in control input and position, the system has strong nonlinearity. By model transformation and introducing new error variable, we successfully remove the nonlinearity and achieve containment control.
- (3)
- In the process of analysis, we introduce a geometrical method which uses two similar triangles. This method solves the problem in the proof of effectiveness of our algorithm.
Of course, there are still many shortcomings in our current work. In future study, we will take the dynamic situation of leaders into consideration. Meanwhile, we hope to make better analysis and results against interference, and therefore, the algorithm may get closer to practical application.
Author Contributions
Conceptualization, N.G. and Y.Y.; methodology, N.G.; software, N.G.; formal analysis, N.G. and Y.Y.; resources, Y.Y.; data curation, N.G.; writing—original draft preparation, N.G.; writing—review and editing, N.G.; visualization, N.G.; supervision, Y.Y.; project administration, Y.Y. All authors have read and agreed to the published version of the manuscript.
Funding
This research was funded by the National Key Research and Development Program of China (2017YFC1500904) and the National Key Research and Development Program of China (2016YFB0501301).
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
Not applicable.
Conflicts of Interest
The authors declare no conflict of interest.
References
- Ji, M.; Ferrari-Trecate, G.; Egerstedt, M.; Buffa, A. Containment Control in Mobile Networks. IEEE Trans. Autom. Control. 2008, 53, 1972–1975. [Google Scholar] [CrossRef] [Scilit]
- Jiang, Y.; Schmidt, J. Motion of dust ejected from the surface of asteroid (101955) Bennu. Heliyon 2020, 6, e05275. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Liu, Y.; Jiang, Y.; Li, H. Bifurcations of relative equilibrium points during homotopy deformation of asteroids. Celest. Mech. Dyn. Astron. 2021, 133, 42. [Google Scholar] [CrossRef] [Scilit]
- Qiang, L.; Yu, J.; Zhang, Y.; Gao, Y.; Guo, X.; Cui, R.; Wang, S.; Guo, W.; Lv, T.; Cai, L.; et al. Optimal attitude control for solar array orientation. Open Astron. 2021, 30, 73–82. [Google Scholar]
- Zhan, C.; Jiang, Y.; Li, H.; Liu, Y. Dynamics and control of typical orbits around Saturn. Appl. Sci. 2022, 12, 1462. [Google Scholar] [CrossRef] [Scilit]
- Liu, Y.; Jiang, Y.; Li, H. Bifurcations of periodic orbits in the gravitational field of irregular bodies: Applications to Bennu and Steins. Aerospace 2022, 9, 151. [Google Scholar] [CrossRef] [Scilit]
- Li, J.; Ren, W.; Xu, S. Distributed Containment Control with Multiple Dynamic Leaders for Double-Integrator Dynamics Using Only Position Measurements. IEEE Trans. Autom. Control. 2012, 57, 1553–1559. [Google Scholar] [CrossRef] [Scilit]
- Liu, H.; Xie, G.; Wang, L. Necessary and sufficient conditions for containment control of networked multi-agent systems. Automatica 2012, 48, 1415–1422. [Google Scholar] [CrossRef] [Scilit]
- Notarstefano, G.; Egerstedt, M.; Haque, M. Containment in leaderfollower networks with switching communication topologies. Automatica 2011, 47, 1035–1040. [Google Scholar] [CrossRef] [Scilit]
- Su, H.; Jia, G.; Chen, M.Z. Semi-global containment control of multi-agent systems with intermittent input saturation. J. Frankl. Inst. 2015, 352, 3504–3525. [Google Scholar] [CrossRef] [Scilit]
- Xu, C.; Zheng, Y.; Su, H.; Zhang, C.; Chen, M.Z. Necessary and sufficient conditions for distributed containment control of multi-agent systems without velocity measurement. IET Control. Theory Appl. 2014, 8, 1752–1759. [Google Scholar] [CrossRef] [Scilit]
- Wang, X.; Li, S.; Shi, P. Distributed Finite-Time Containment Control for Double-Integrator Multiagent Systems. IEEE Trans. Cybern. 2014, 44, 1518–1528. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Zhang, J.; Li, W.; Xie, L. Containment control of leader-following multi-agent systems with Markovian switching network topologies and measurement noises. Automatica 2015, 51, 263–267. [Google Scholar]
- Kan, Z.; Shea, J.M.; Dixon, W.E. Leaderfollower containment control over directed random graphs. Automatica 2016, 6, 56–62. [Google Scholar] [CrossRef] [Scilit]
- Su, H.; Chen, M.Z.Q.; Wang, X.; Lam, J. Semiglobal Observer-Based Leader-Following Consensus with Input Saturation. IEEE Trans. Ind. Electron. 2014, 61, 2842–2850. [Google Scholar] [CrossRef] [Scilit]
- Liu, K.; Xie, G.; Wang, L. Containment control for second-order multi-agent systems with time-varying delays. Syst. Control. Lett. 2014, 67, 24–31. [Google Scholar] [CrossRef] [Scilit]
- Song, Q.; Liu, F.; Su, H.; Vasilakos, A.V. Semiglobal and global containment control of multiagent systems with secondorder dynamics and input saturation. Int. J. Robust Nonlinear Control. 2016, 26, 3439–3670. [Google Scholar] [CrossRef] [Scilit]
- Ren, W.; Meng, Z.; You, Z. Distributed finite-time attitude containment control for multiple rigid bodies. Automatica 2010, 46, 2092–2099. [Google Scholar]
- Su, H.; Chen, M.Z.Q. Multi-agent containment control with input saturation on switching topologies. IET Control. Theory Appl. 2015, 9, 399–409. [Google Scholar] [CrossRef] [Scilit]
- Lin, P.; Xu, J.; Ren, W.; Yang, C.; Gui, W. Angle-Based Analysis Approach for Distributed Constrained Optimization. IEEE Trans. Autom. Control. 2021, 66, 5569–5576. [Google Scholar] [CrossRef] [Scilit]
- Lin, P.; Ren, W.; Farrell, J. Distributed Continuous-Time Optimization: Nonuniform Gradient Gains, Finite-Time Convergence, and Convex Constraint Set. IEEE Trans. Autom. Control. 2017, 62, 2239–2253. [Google Scholar] [CrossRef] [Scilit]
- Lian, F.; Chakrabortty, A.; Duel-Hallen, A. Game-Theoretic Multi-Agent Control and Network Cost Allocation Under Communication Constraints. IEEE J. Sel. Areas Commun. 2017, 35, 330–340. [Google Scholar] [CrossRef] [Scilit]
- Delaram, J.; Houshamand, M.; Ashtiani, F.; Valilai, O.F. A utility-based matching mechanism for stable and optimal resource allocation in cloud manufacturing platforms using deferred acceptance algorithm. J. Manuf. Syst. 2021, 60, 569–584. [Google Scholar] [CrossRef] [Scilit]
- Bakolas, E.; Lee, Y. Decentralized game-theoretic control for dynamic task allocation problems for multi-agent systems. In Proceedings of the 2021 American Control Conference (ACC), New Orleans, LA, USA, 25–28 May 2021; pp. 3228–3233. [Google Scholar]
- Fan, W.; Wang, S.; Gu, X.; Zhou, Z.; Zhao, Y.; Huo, W. Evolutionary game analysis on industrial pollution control of local government in China. J. Environ. Manag. 2021, 298, 113499. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Sathishkumar, M.; Liu, Y.-C. Resilient Memory Event-triggered Consensus Control for Multi-Agent Systems with Aperiodic DoS Attacks. Int. J. Control. Autom. Syst. 2022, 20, 1800–1813. [Google Scholar] [CrossRef] [Scilit]
- Lin, P.; Ren, W.; Yang, C.; Gui, W. Distributed Continuous-Time and Discrete-Time Optimization with Nonuniform Unbounded Convex Constraint Sets and Nonuniform Stepsizes. IEEE Trans. Autom. Control. 2019, 64, 5148–5155. [Google Scholar] [CrossRef] [Scilit]
- Lin, P.; Ren, W.; Yang, C.; Gui, W. Distributed Consensus of Second-Order Multiagent Systems with Nonconvex Velocity and Control Input Constraints. IEEE Trans. Autom. Control. 2018, 63, 1171–1176. [Google Scholar] [CrossRef] [Scilit]
- Lin, P.; Ren, W.; Gao, H. Distributed Velocity-Constrained Consensus of Discrete-Time Multi-Agent Systems with Nonconvex Constraints, Switching Topologies, and Delays. IEEE Trans. Autom. Control. 2017, 62, 5788–5794. [Google Scholar] [CrossRef] [Scilit]
- Yang, C.; Duan, M.; Lin, P.; Ren, W.; Gui, W. Distributed Containment Control of Continuous-Time Multiagent Systems with Nonconvex Control Input Constraints. IEEE Trans. Ind. Electron. 2019, 66, 7927–7934. [Google Scholar] [CrossRef] [Scilit]
- Lin, P.; Li, G.; Huang, K. Position-constrained containment for second-order discrete-time multi-agent systems. Syst. Control. Lett. 2020, 142, 104–109. [Google Scholar] [CrossRef] [Scilit]
- Lin, P.; Ren, W.; Yang, C.; Gui, W. Distributed Optimization with Nonconvex Velocity Constraints, Nonuniform Position Constraints, and Nonuniform Stepsizes. IEEE Trans. Autom. Control. 2019, 64, 2575–2582. [Google Scholar] [CrossRef] [Scilit]
- Facchinei, F.; Pang, J.S. Finite-Dimensional Variational Inequalities and Complementarity Problems; Springer: New York, NY, USA, 2003. [Google Scholar]
Publisher’s Note: MDPI stays neutral with regard to jurisdictional claims in published maps and institutional affiliations. |
© 2022 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).