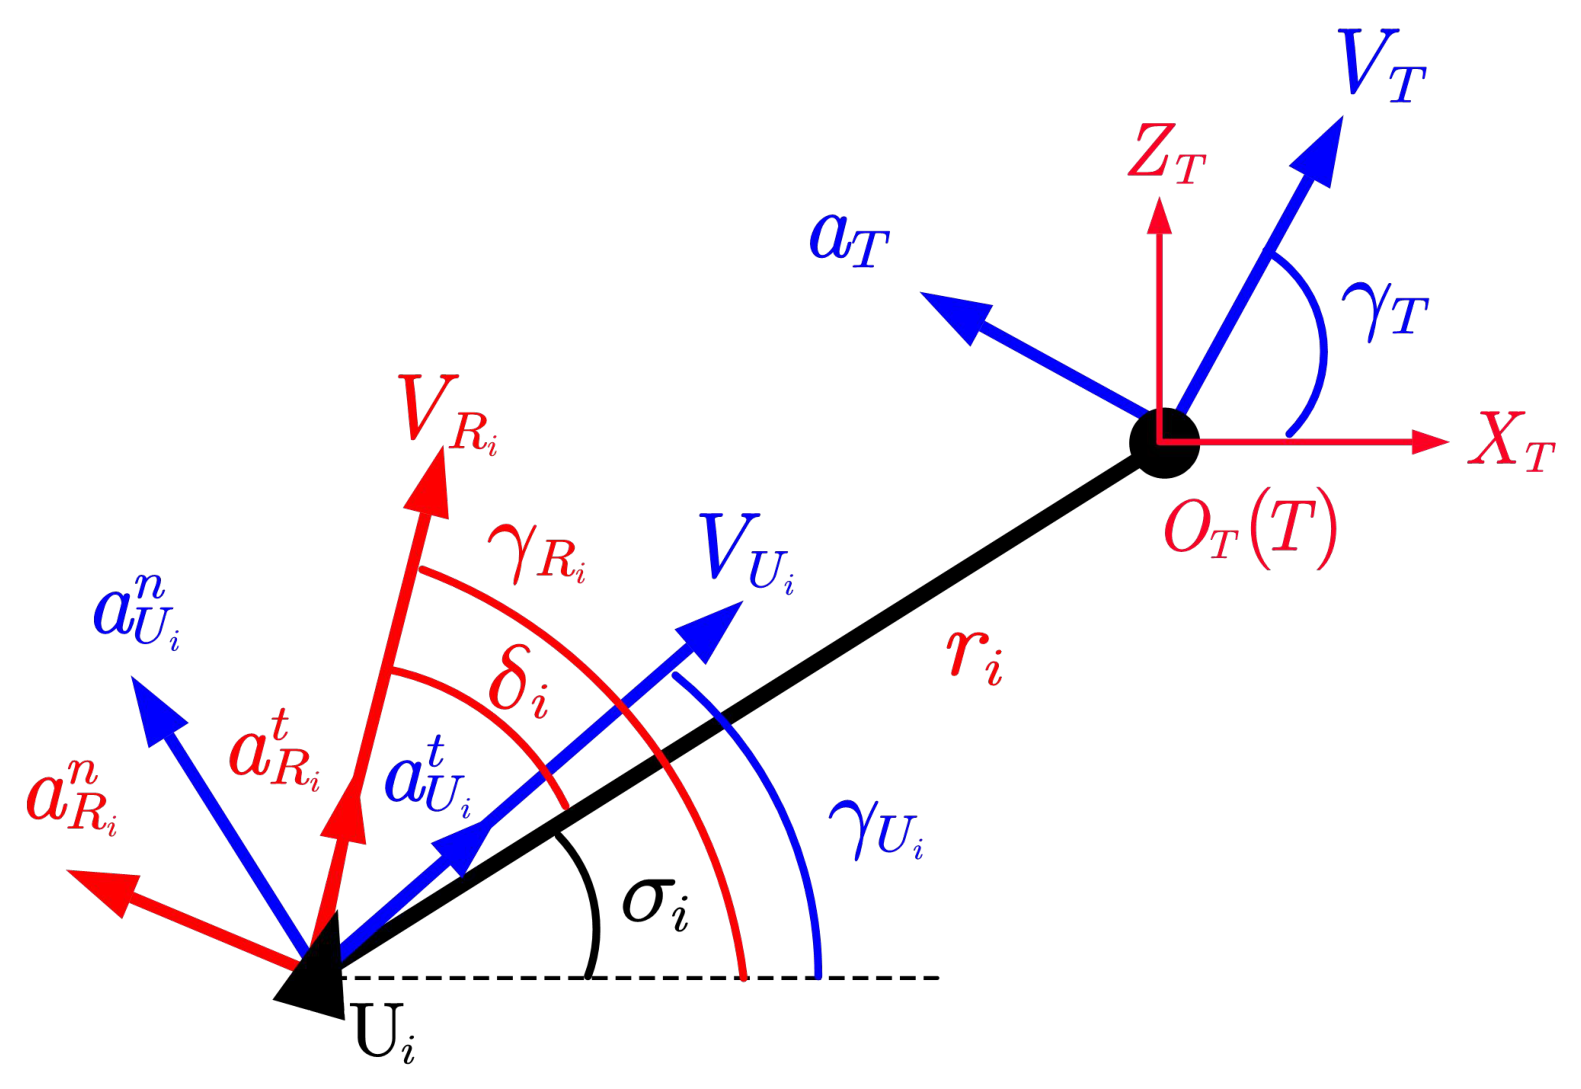
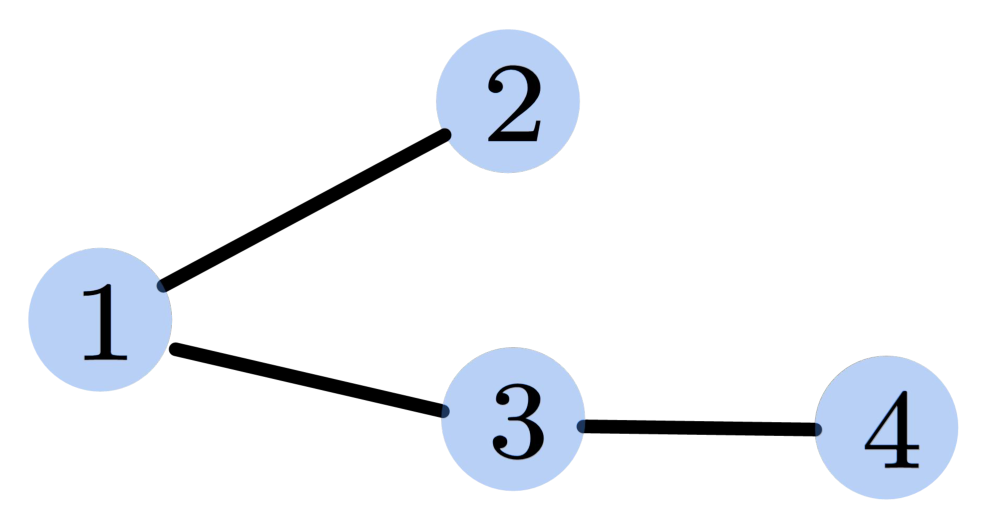
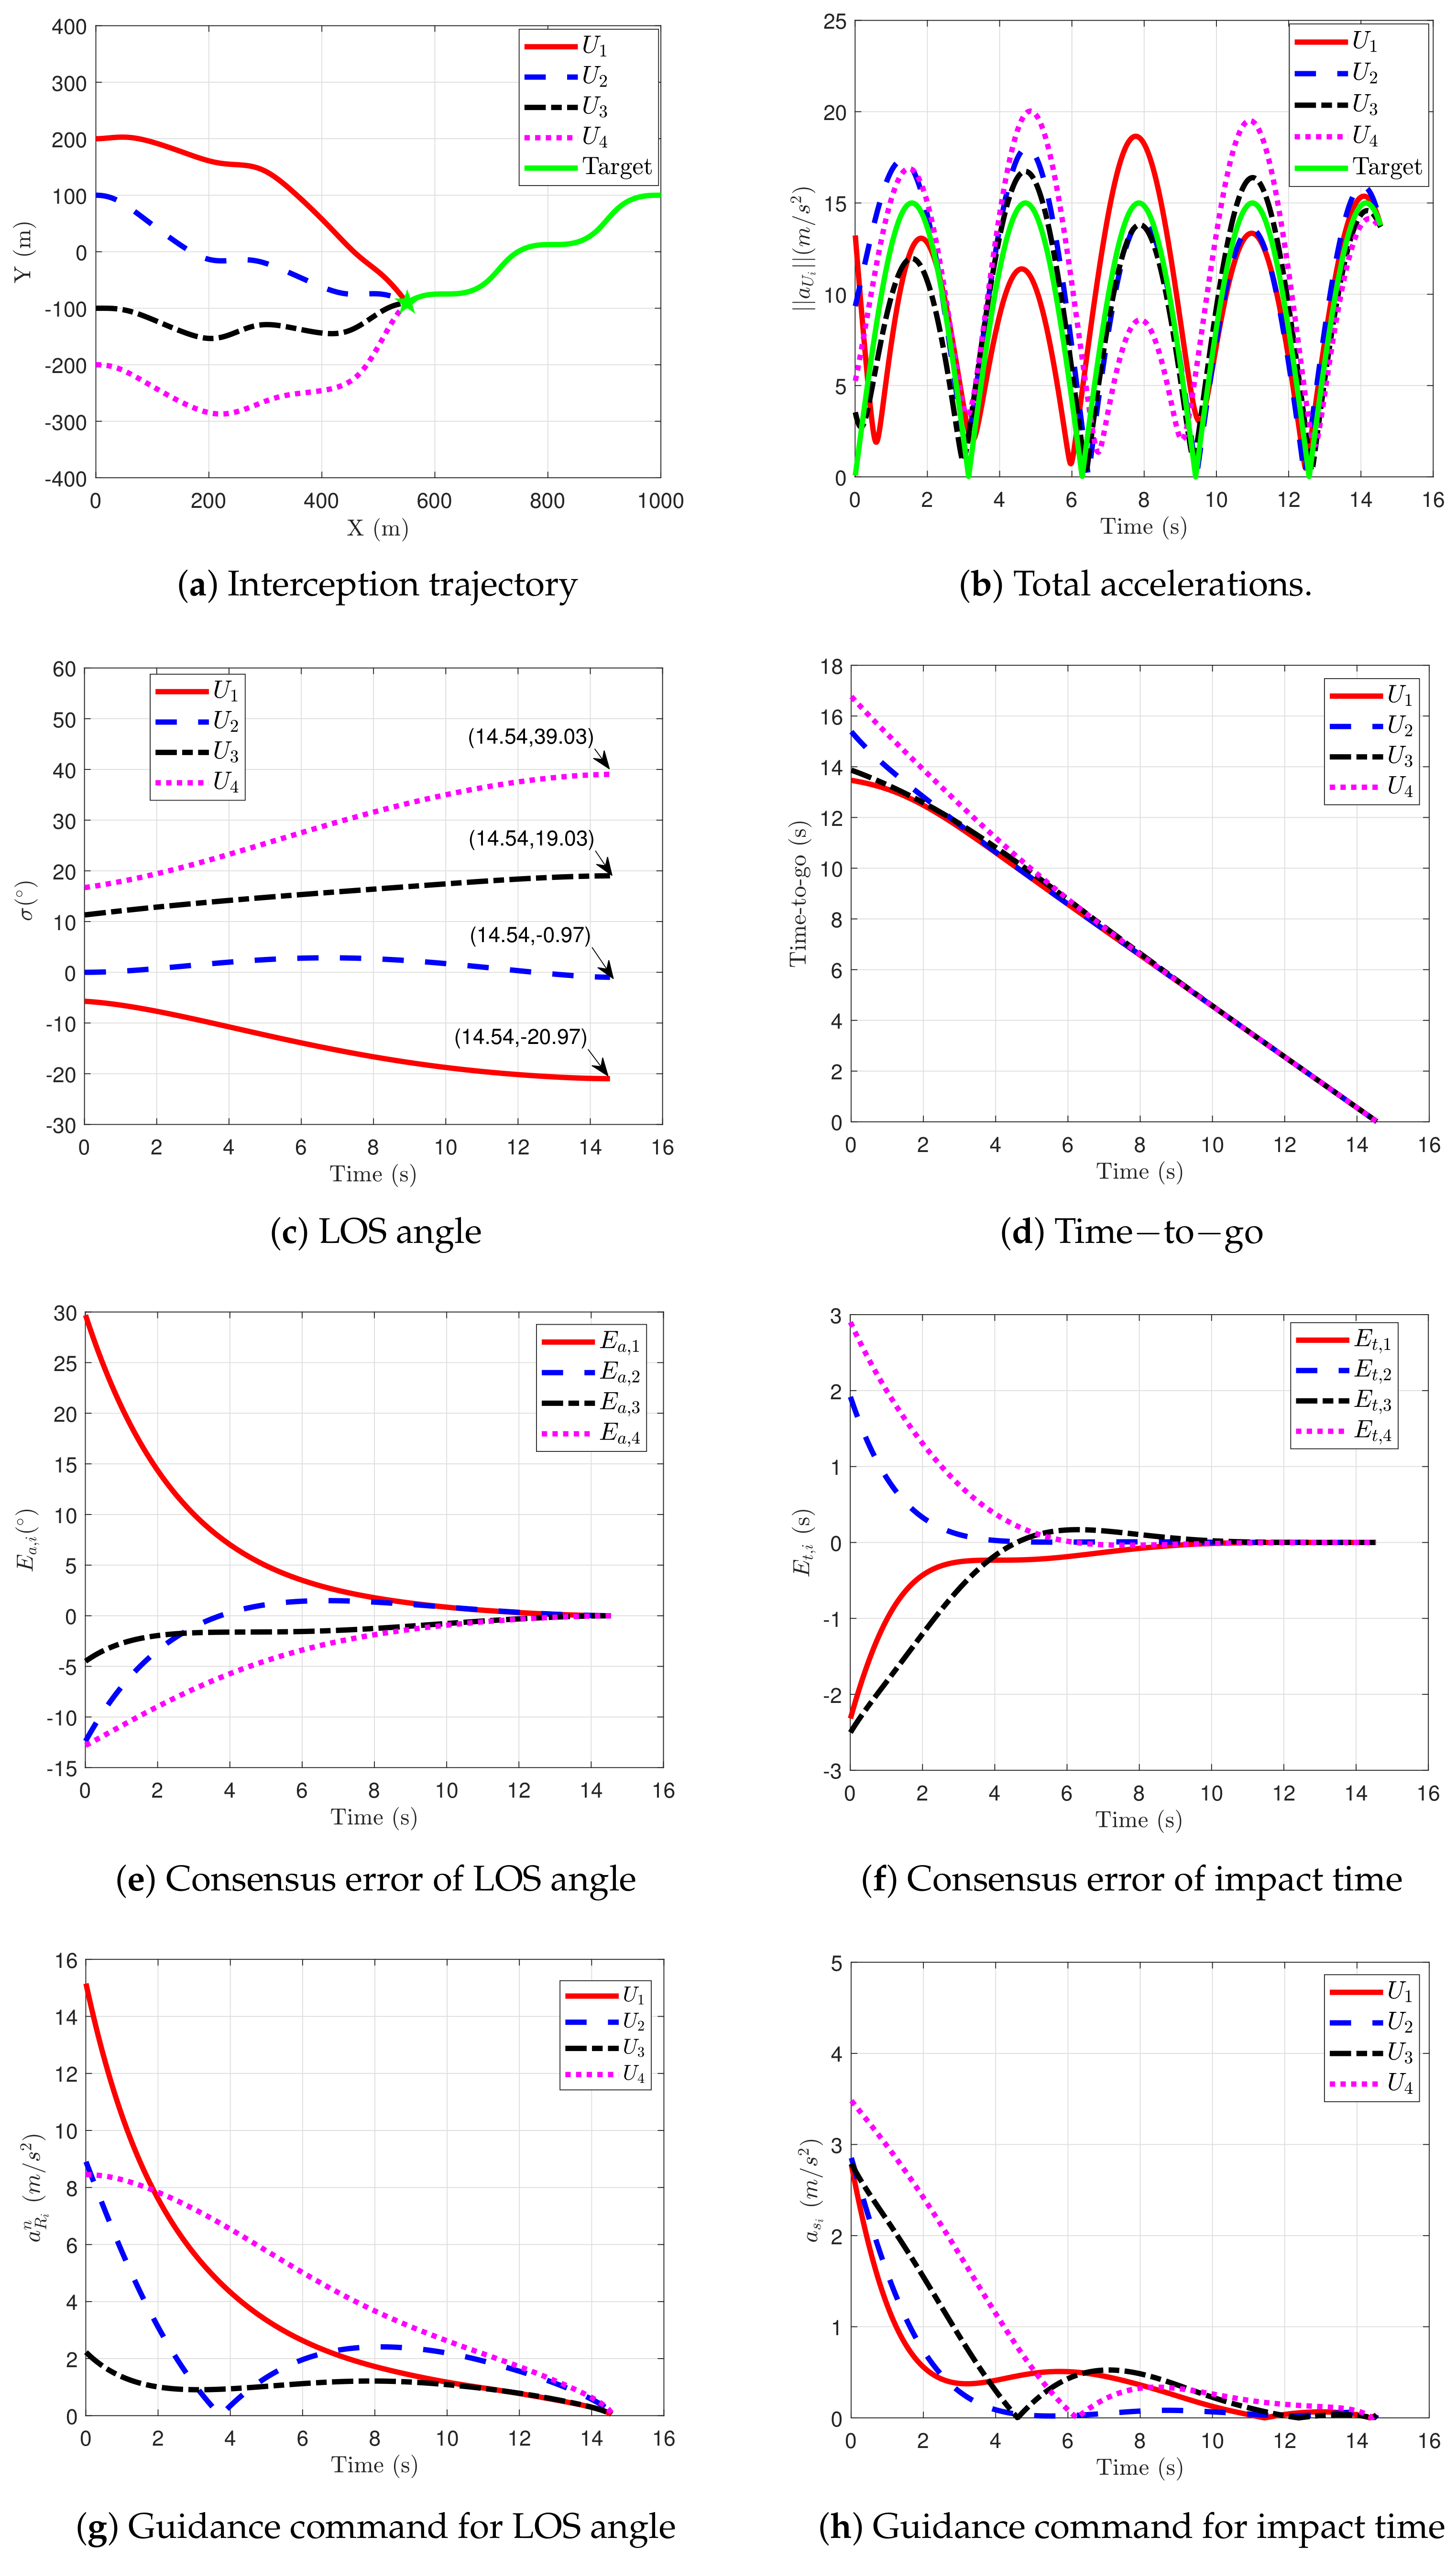
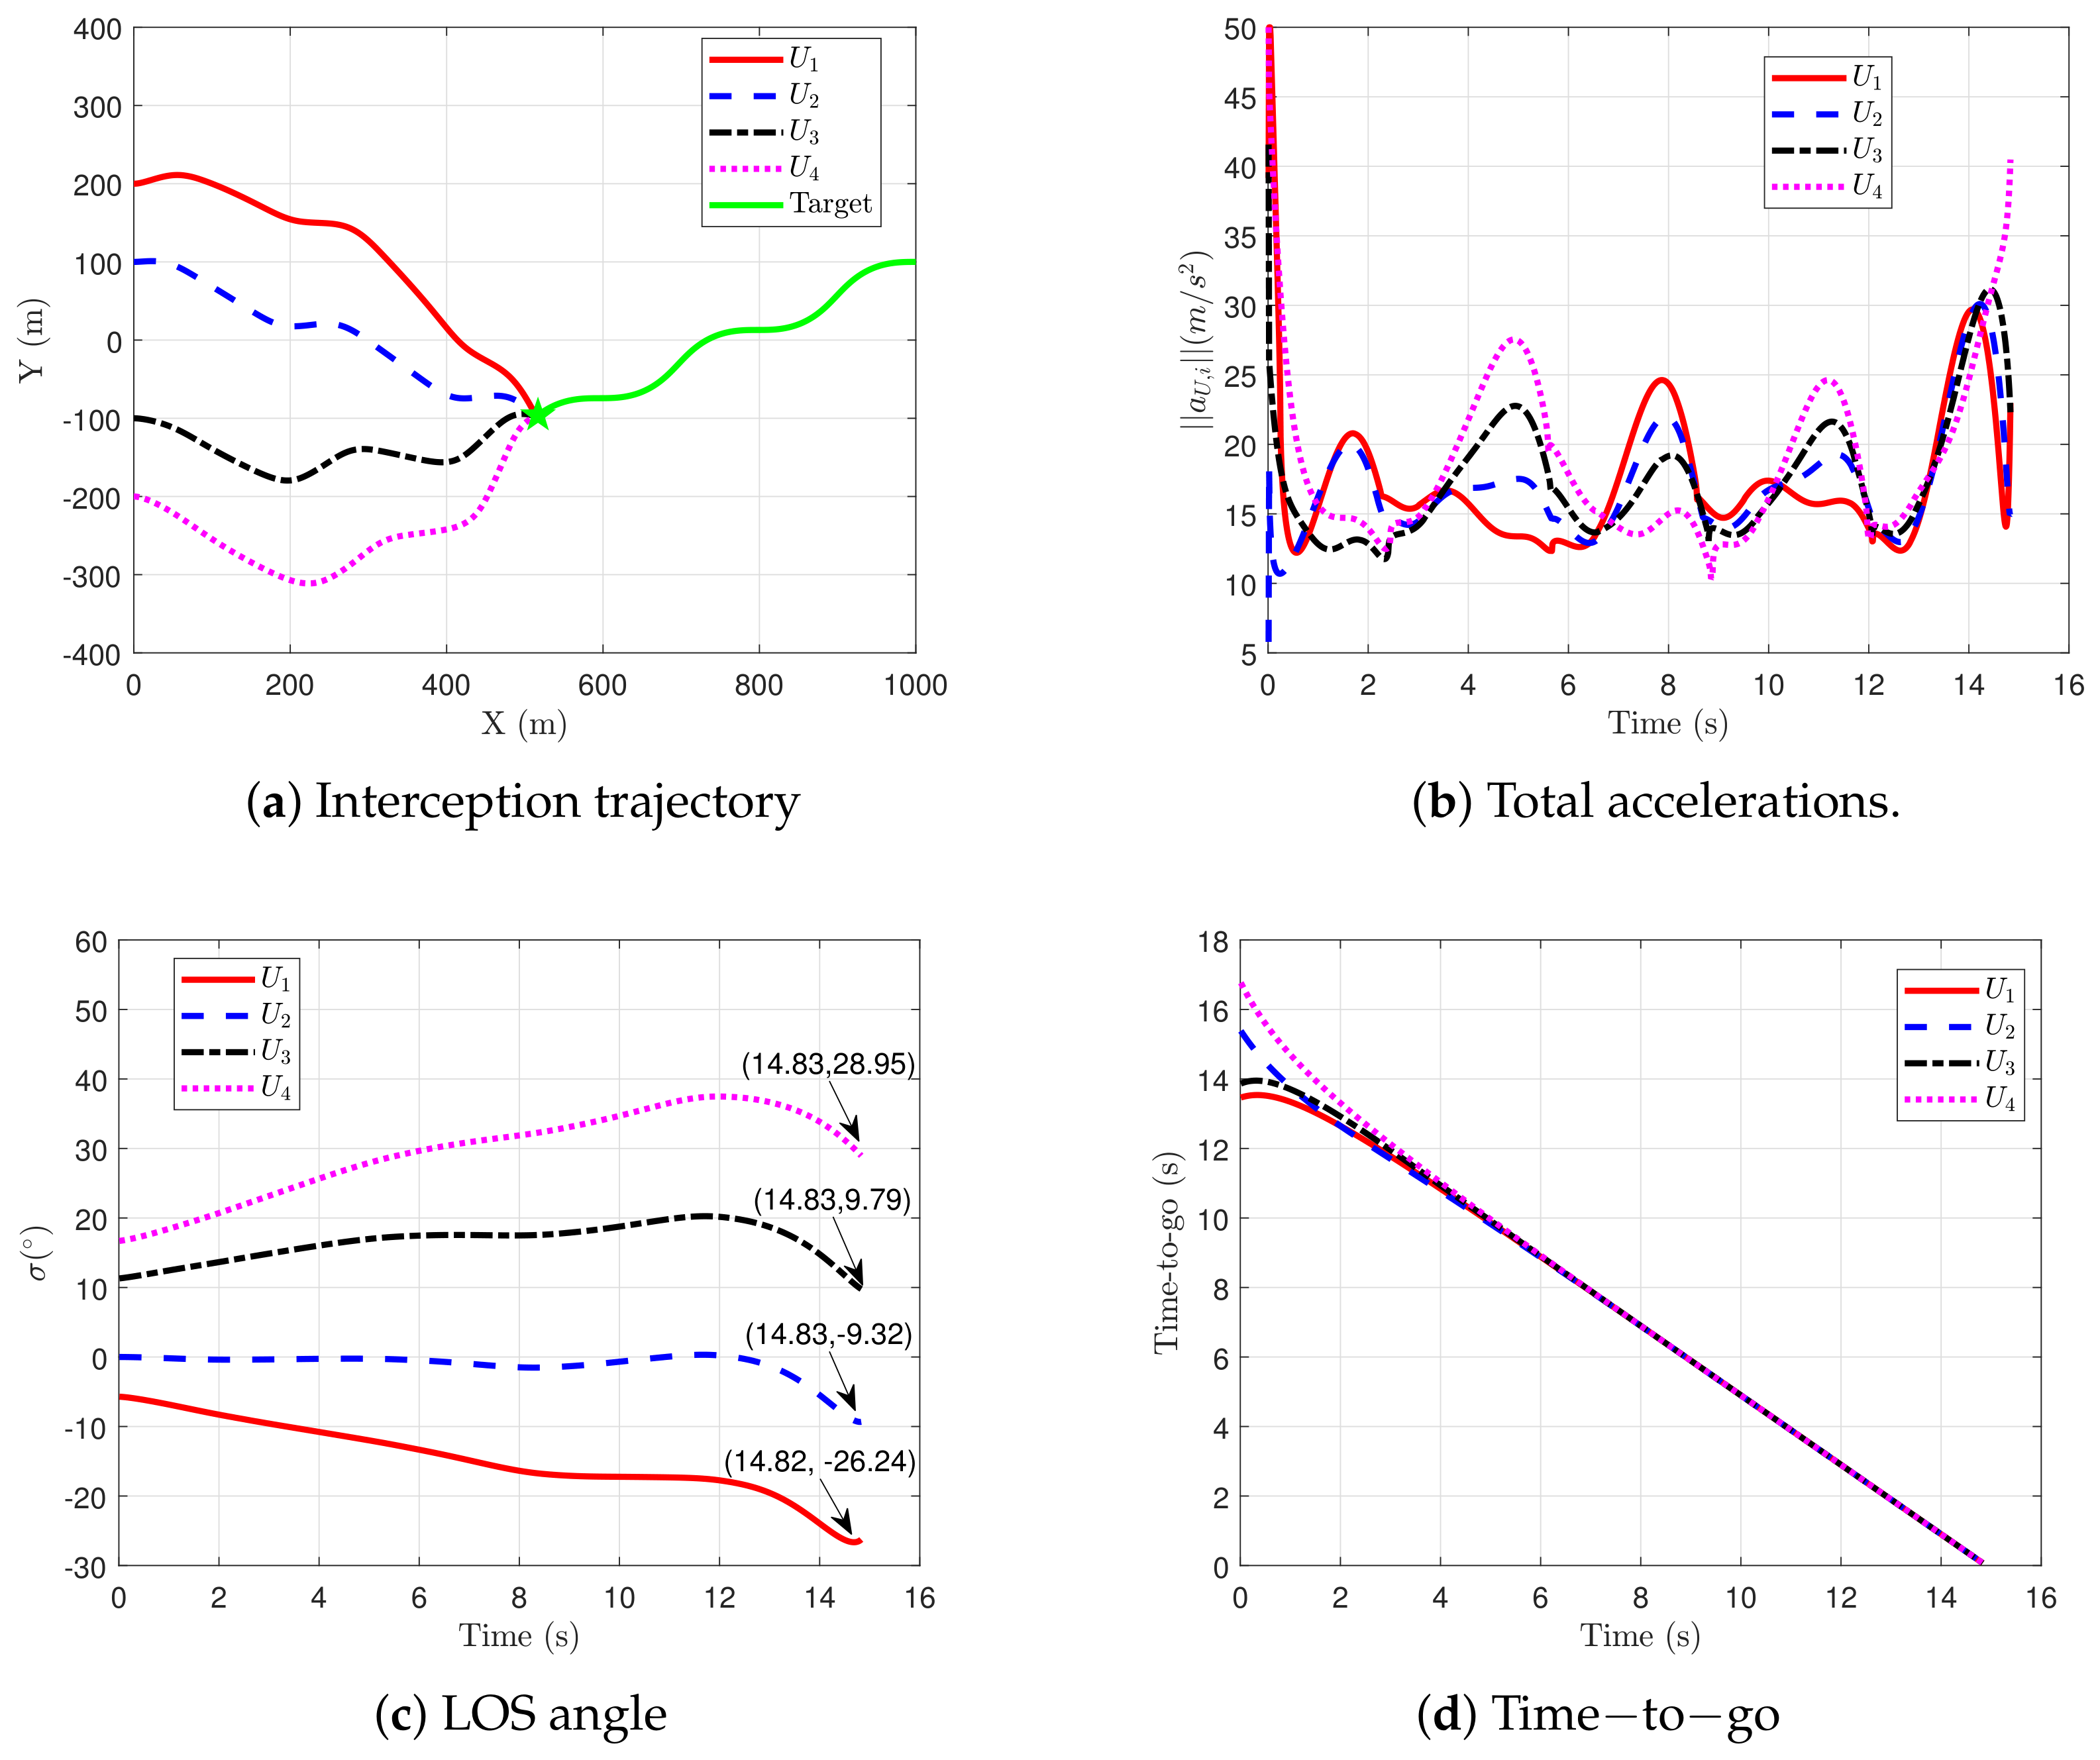
Distributed Optimal Spatial–Temporal Cooperative Pursuit Guidance for Multi-UAV Interception

Abstract
1. Introduction
- 1.
- An optimal terminal consensus protocol is proposed to solve a distributed cooperative guidance problem. Since the proposed protocol minimizes the performance index associated with energy consumption, it is believed to consume less effort than existing consensus-based approaches.
- 2.
- The proposed two-dimensional and three-dimensional spatial–temporal cooperative law constrains the relative interception geometry rather than absolute angles, which will be more feasible and energy-efficient.
2. Problem Formulation and Preliminaries
2.1. Problem Formulation
2.2. Communication Topology Based on Graph Theory
3. Distributed Spatial–Temporal Cooperative Guidance
3.1. Design of Proposed Method
3.2. Convergence Analysis of Proposed Method
4. Design of Three-Dimensional Distributed Cooperative Guidance
5. Simulation Results
5.1. Performance of Proposed Method in Two-Dimensional Space
5.2. Comparative Simulation
5.3. Validation of Three Distributed Cooperative Guidance
6. Conclusions
Author Contributions
Funding
Data Availability Statement
Conflicts of Interest
References
- Olfati-Saber, R.; Murray, R.M. Consensus problems in networks of agents with switching topology and time-delays. IEEE Trans. Autom. Control 2004, 49, 1520–1533. [Google Scholar] [CrossRef] [Scilit]
- Ren, W.; Beard, R.W. Distributed Consensus in Multi-Vehicle Cooperative Control; Springer: London, UK, 2008; Volume 27. [Google Scholar]
- Zhao, S.; Zhou, R. Cooperative guidance for multimissile salvo attack. Chin. J. Aeronaut. 2008, 21, 533–539. [Google Scholar] [CrossRef] [Scilit]
- He, S.; Wang, W.; Lin, D.; Lei, H. Consensus-based two-stage salvo attack guidance. IEEE Trans. Aerosp. Electron. Syst. 2017, 54, 1555–1566. [Google Scholar] [CrossRef] [Scilit]
- Li, K.; Wang, J.; Lee, C.H.; Zhou, R.; Zhao, S. Distributed cooperative guidance for multivehicle simultaneous arrival without numerical singularities. J. Guid. Control Dyn. 2020, 43, 1365–1373. [Google Scholar] [CrossRef] [Scilit]
- Chen, Y.; Wang, J.; Wang, C.; Shan, J.; Xin, M. Three-dimensional cooperative homing guidance law with field-of-view constraint. J. Guid. Control Dyn. 2020, 43, 389–397. [Google Scholar] [CrossRef] [Scilit]
- Chen, Y.; Guo, D.; Wang, J.; Shan, J.; Xin, M. Cooperative circular guidance with nonuniform field-of-view constraints. J. Guid. Control Dyn. 2022, 45, 1435–1450. [Google Scholar] [CrossRef] [Scilit]
- Yang, X.; Zhang, Y.; Song, S. Two-stage cooperative guidance strategy with impact-angle and field-of-view constraints. J. Guid. Control Dyn. 2023, 46, 590–599. [Google Scholar] [CrossRef] [Scilit]
- Zhou, J.; Yang, J. Distributed guidance law design for cooperative simultaneous attacks with multiple missiles. J. Guid. Control Dyn. 2016, 39, 2439–2447. [Google Scholar] [CrossRef] [Scilit]
- Song, J.; Song, S.; Xu, S. Three-dimensional cooperative guidance law for multiple missiles with finite-time convergence. Aerosp. Sci. Technol. 2017, 67, 193–205. [Google Scholar] [CrossRef] [Scilit]
- Kumar, S.R.; Mukherjee, D. Cooperative salvo guidance using finite-time consensus over directed cycles. IEEE Trans. Aerosp. Electron. Syst. 2019, 56, 1504–1514. [Google Scholar] [CrossRef] [Scilit]
- Zhang, S.; Guo, Y.; Liu, Z.; Wang, S.; Hu, X. Finite-time cooperative guidance strategy for impact angle and time control. IEEE Trans. Aerosp. Electron. Syst. 2020, 57, 806–819. [Google Scholar] [CrossRef] [Scilit]
- Sinha, A.; Kumar, S.R. Supertwisting control-based cooperative salvo guidance using leader-follower approach. IEEE Trans. Aerosp. Electron. Syst. 2020, 57, 3357–3367. [Google Scholar] [CrossRef] [Scilit]
- Nanavati, R.; Kumar, S.R.; Maity, A. Cooperative target capture using relative separation for three-dimensional engagement. IEEE Trans. Aerosp. Electron. Syst. 2021, 57, 3357–3367. [Google Scholar] [CrossRef] [Scilit]
- Sinha, A.; Kumar, S.R.; Mukherjee, D. Three-dimensional nonlinear cooperative salvo using event-triggered strategy. J. Guid. Control Dyn. 2021, 44, 328–342. [Google Scholar] [CrossRef] [Scilit]
- Polyakov, A. Nonlinear feedback design for fixed-time stabilization of linear control systems. IEEE Trans. Autom. Control 2011, 57, 2106–2110. [Google Scholar] [CrossRef] [Scilit]
- Zuo, Z.; Tian, B.; Defoort, M.; Ding, Z. Fixed-time consensus tracking for multiagent systems with high-order integrator dynamics. IEEE Trans. Autom. Control 2017, 63, 563–570. [Google Scholar] [CrossRef] [Scilit]
- Dong, W.; Wang, C.; Wang, J.; Zuo, Z.; Shan, J. Fixed-time terminal angle-constrained cooperative guidance law against maneuvering target. IEEE Trans. Aerosp. Electron. Syst. 2022, 58, 1352–1366. [Google Scholar] [CrossRef] [Scilit]
- Wang, C.; Dong, W.; Wang, J.; Xin, M. Impact-angle-constrained cooperative guidance for salvo attack. J. Guid. Control Dyn. 2022, 45, 684–703. [Google Scholar] [CrossRef] [Scilit]
- Zhang, L.; Li, D.; Jing, L.; Ju, X.; Cui, N. Appointed-Time Cooperative Guidance Law with Line-of-Sight Angle Constraint and Time-to-go Control. IEEE Trans. Aerosp. Electron. Syst. 2023, 59, 3142–3155. [Google Scholar] [CrossRef] [Scilit]
- Tang, J.; Zuo, Z. Cooperative circular guidance of multiple missiles: A practical prescribed-time consensus approach. J. Guid. Control Dyn. 2023, 46, 1–15. [Google Scholar] [CrossRef] [Scilit]
- Tao, H.; Li, H.; Wang, J.; Song, T.; Lin, D. Analytical near-optimal distributed consensus for cooperative salvo guidance. J. Guid. Control Dyn. 2024, 47, 1499–1506. [Google Scholar] [CrossRef] [Scilit]
- Chen, Y.; Wang, J.; Shan, J.; Xin, M. Cooperative guidance for multiple powered missiles with constrained impact and bounded speed. J. Guid. Control Dyn. 2021, 44, 825–841. [Google Scholar] [CrossRef] [Scilit]
- Yu, H.; Dai, K.; Li, H.; Zou, Y.; Ma, X.; Ma, S.; Zhang, H. Three-dimensional adaptive fixed-time cooperative guidance law with impact time and angle constraints. Aerosp. Sci. Technol. 2022, 123, 107450. [Google Scholar] [CrossRef] [Scilit]
- Shaferman, V.; Shima, T. Cooperative optimal guidance laws for imposing a relative intercept angle. J. Guid. Control Dyn. 2015, 38, 1395–1408. [Google Scholar] [CrossRef] [Scilit]
- Shaferman, V.; Shima, T. Cooperative differential games guidance laws for imposing a relative intercept angle. J. Guid. Control Dyn. 2017, 40, 2465–2480. [Google Scholar] [CrossRef] [Scilit]
- Ma, Z.; Wang, Q. Bipartite consensus control of uncertain heterogeneous unmanned systems under communication failures. Nonlinear Dyn. 2026, 114, 263. [Google Scholar] [CrossRef] [Scilit]
- Jeon, I.S.; Cho, H.; Lee, J.I. Exact guidance solution for maneuvering target on relative virtual frame formulation. J. Guid. Control Dyn. 2015, 38, 1330–1340. [Google Scholar] [CrossRef] [Scilit]
- Cho, N.; Kim, Y. Optimality of augmented ideal proportional navigation for maneuvering target interception. IEEE Trans. Aerosp. Electron. Syst. 2016, 52, 948–954. [Google Scholar] [CrossRef] [Scilit]
- Li, H.; He, S.; Wang, J.; Lee, C.H. Optimal encirclement guidance. IEEE Trans. Aerosp. Electron. Syst. 2022, 58, 4327–4341. [Google Scholar] [CrossRef] [Scilit]
- Tao, H.; Lin, D.; Song, T.; Li, H. Optimal spatial-temporal cooperative guidance against a maneuvering target. J. Frankl. Inst. 2023, 360, 9886–9903. [Google Scholar] [CrossRef] [Scilit]



| Position (m) | Speed (m/s) | Flight Path Angle (°) | |
|---|---|---|---|
| (0, 200) | 40 | 0 | |
| (0, 100) | 30 | 0 | |
| (0, −100) | 40 | 0 | |
| (0, −200) | 30 | 0 | |
| Target | (1000, 100) | 35 | 180 |
| Energy | Proposed Approach | Approach in [18] |
|---|---|---|
| 0.81 | 2.44 | |
| 0.99 | 2.30 | |
| 0.83 | 2.42 | |
| 1.09 | 2.91 | |
| Total | 3.72 | 10.07 |
| Vehicle | Position (m) | Velocity (m/s) |
|---|---|---|
| (0, 200, 20) | (40, 0, 0) | |
| (0, 100, 30) | (30, 0, 0) | |
| (0, −100, 40) | (40, 0, 0) | |
| (0, −200, 50) | (30, 0, 0) | |
| Target | (300, 0, 100) | (20, 0, 5) |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Xu, J.; Tao, H.; Lin, D. Distributed Optimal Spatial–Temporal Cooperative Pursuit Guidance for Multi-UAV Interception. Aerospace 2026, 13, 542. https://doi.org/10.3390/aerospace13060542
Xu J, Tao H, Lin D. Distributed Optimal Spatial–Temporal Cooperative Pursuit Guidance for Multi-UAV Interception. Aerospace. 2026; 13(6):542. https://doi.org/10.3390/aerospace13060542
Chicago/Turabian StyleXu, Jiao, Hong Tao, and Defu Lin. 2026. "Distributed Optimal Spatial–Temporal Cooperative Pursuit Guidance for Multi-UAV Interception" Aerospace 13, no. 6: 542. https://doi.org/10.3390/aerospace13060542
APA StyleXu, J., Tao, H., & Lin, D. (2026). Distributed Optimal Spatial–Temporal Cooperative Pursuit Guidance for Multi-UAV Interception. Aerospace, 13(6), 542. https://doi.org/10.3390/aerospace13060542