Article

Hand Prosthesis Sensorimotor Control Inspired by the Human Somatosensory System

1
Research Unit of Advanced Robotics and Human-Centred Technologies, Department of Engineering, Università Campus Bio-Medico di Roma, 00128 Rome, Italy
2
INAIL Centro Protesi, Vigorso di Budrio, 40054 Bologna, Italy
*
Author to whom correspondence should be addressed.
Robotics 2023, 12(5), 136; https://doi.org/10.3390/robotics12050136

Submission received: 11 August 2023 / Revised: 15 September 2023 / Accepted: 28 September 2023 / Published: 30 September 2023
(This article belongs to the Special Issue Intelligent Bionic Robots)

Abstract

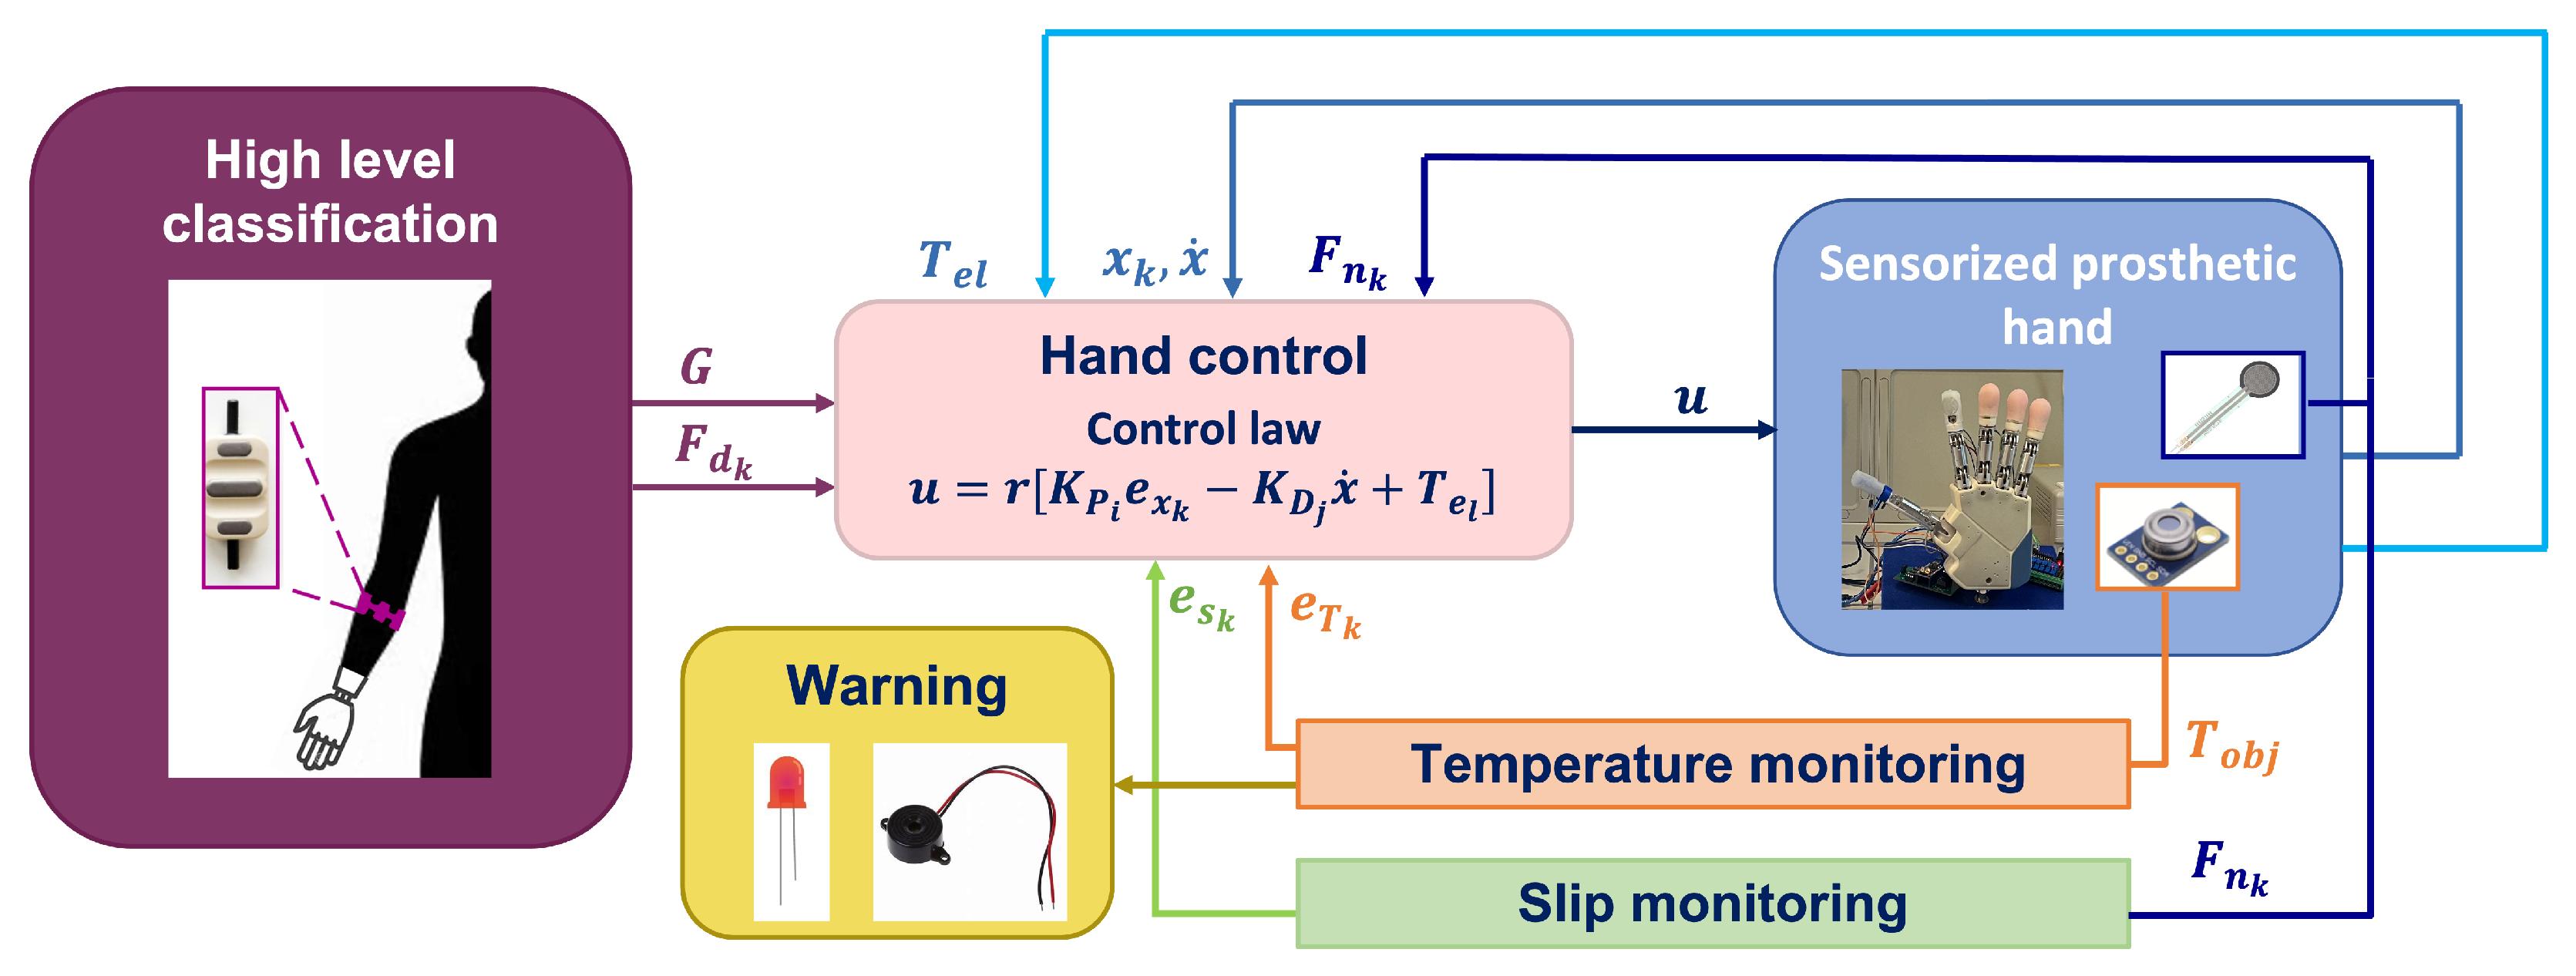
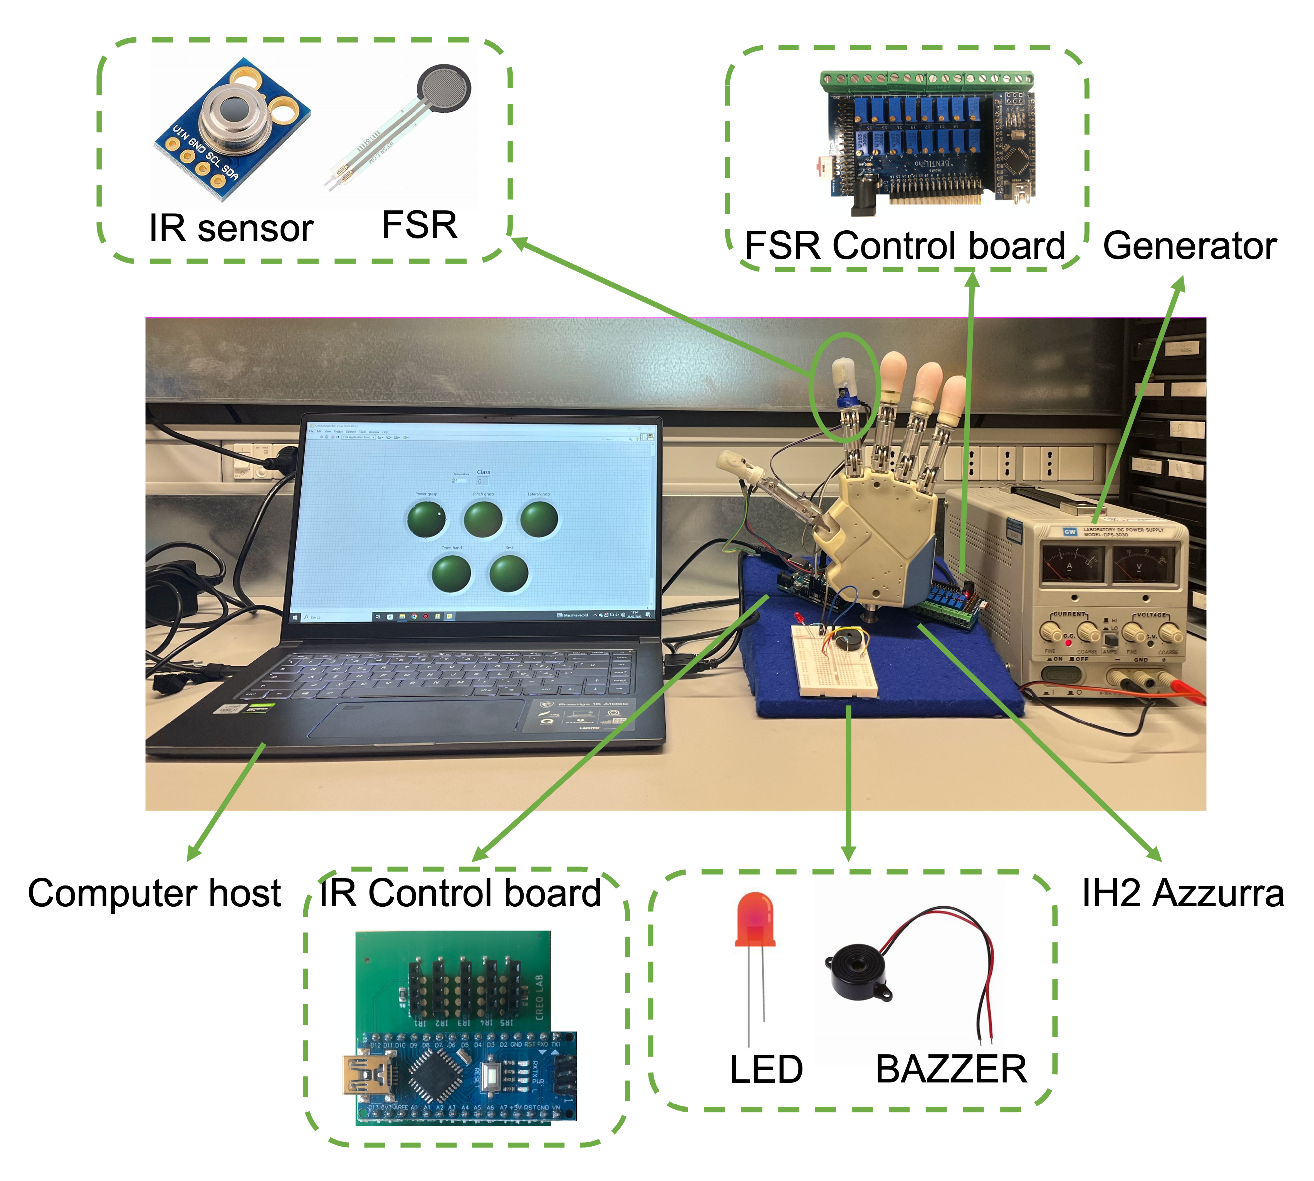
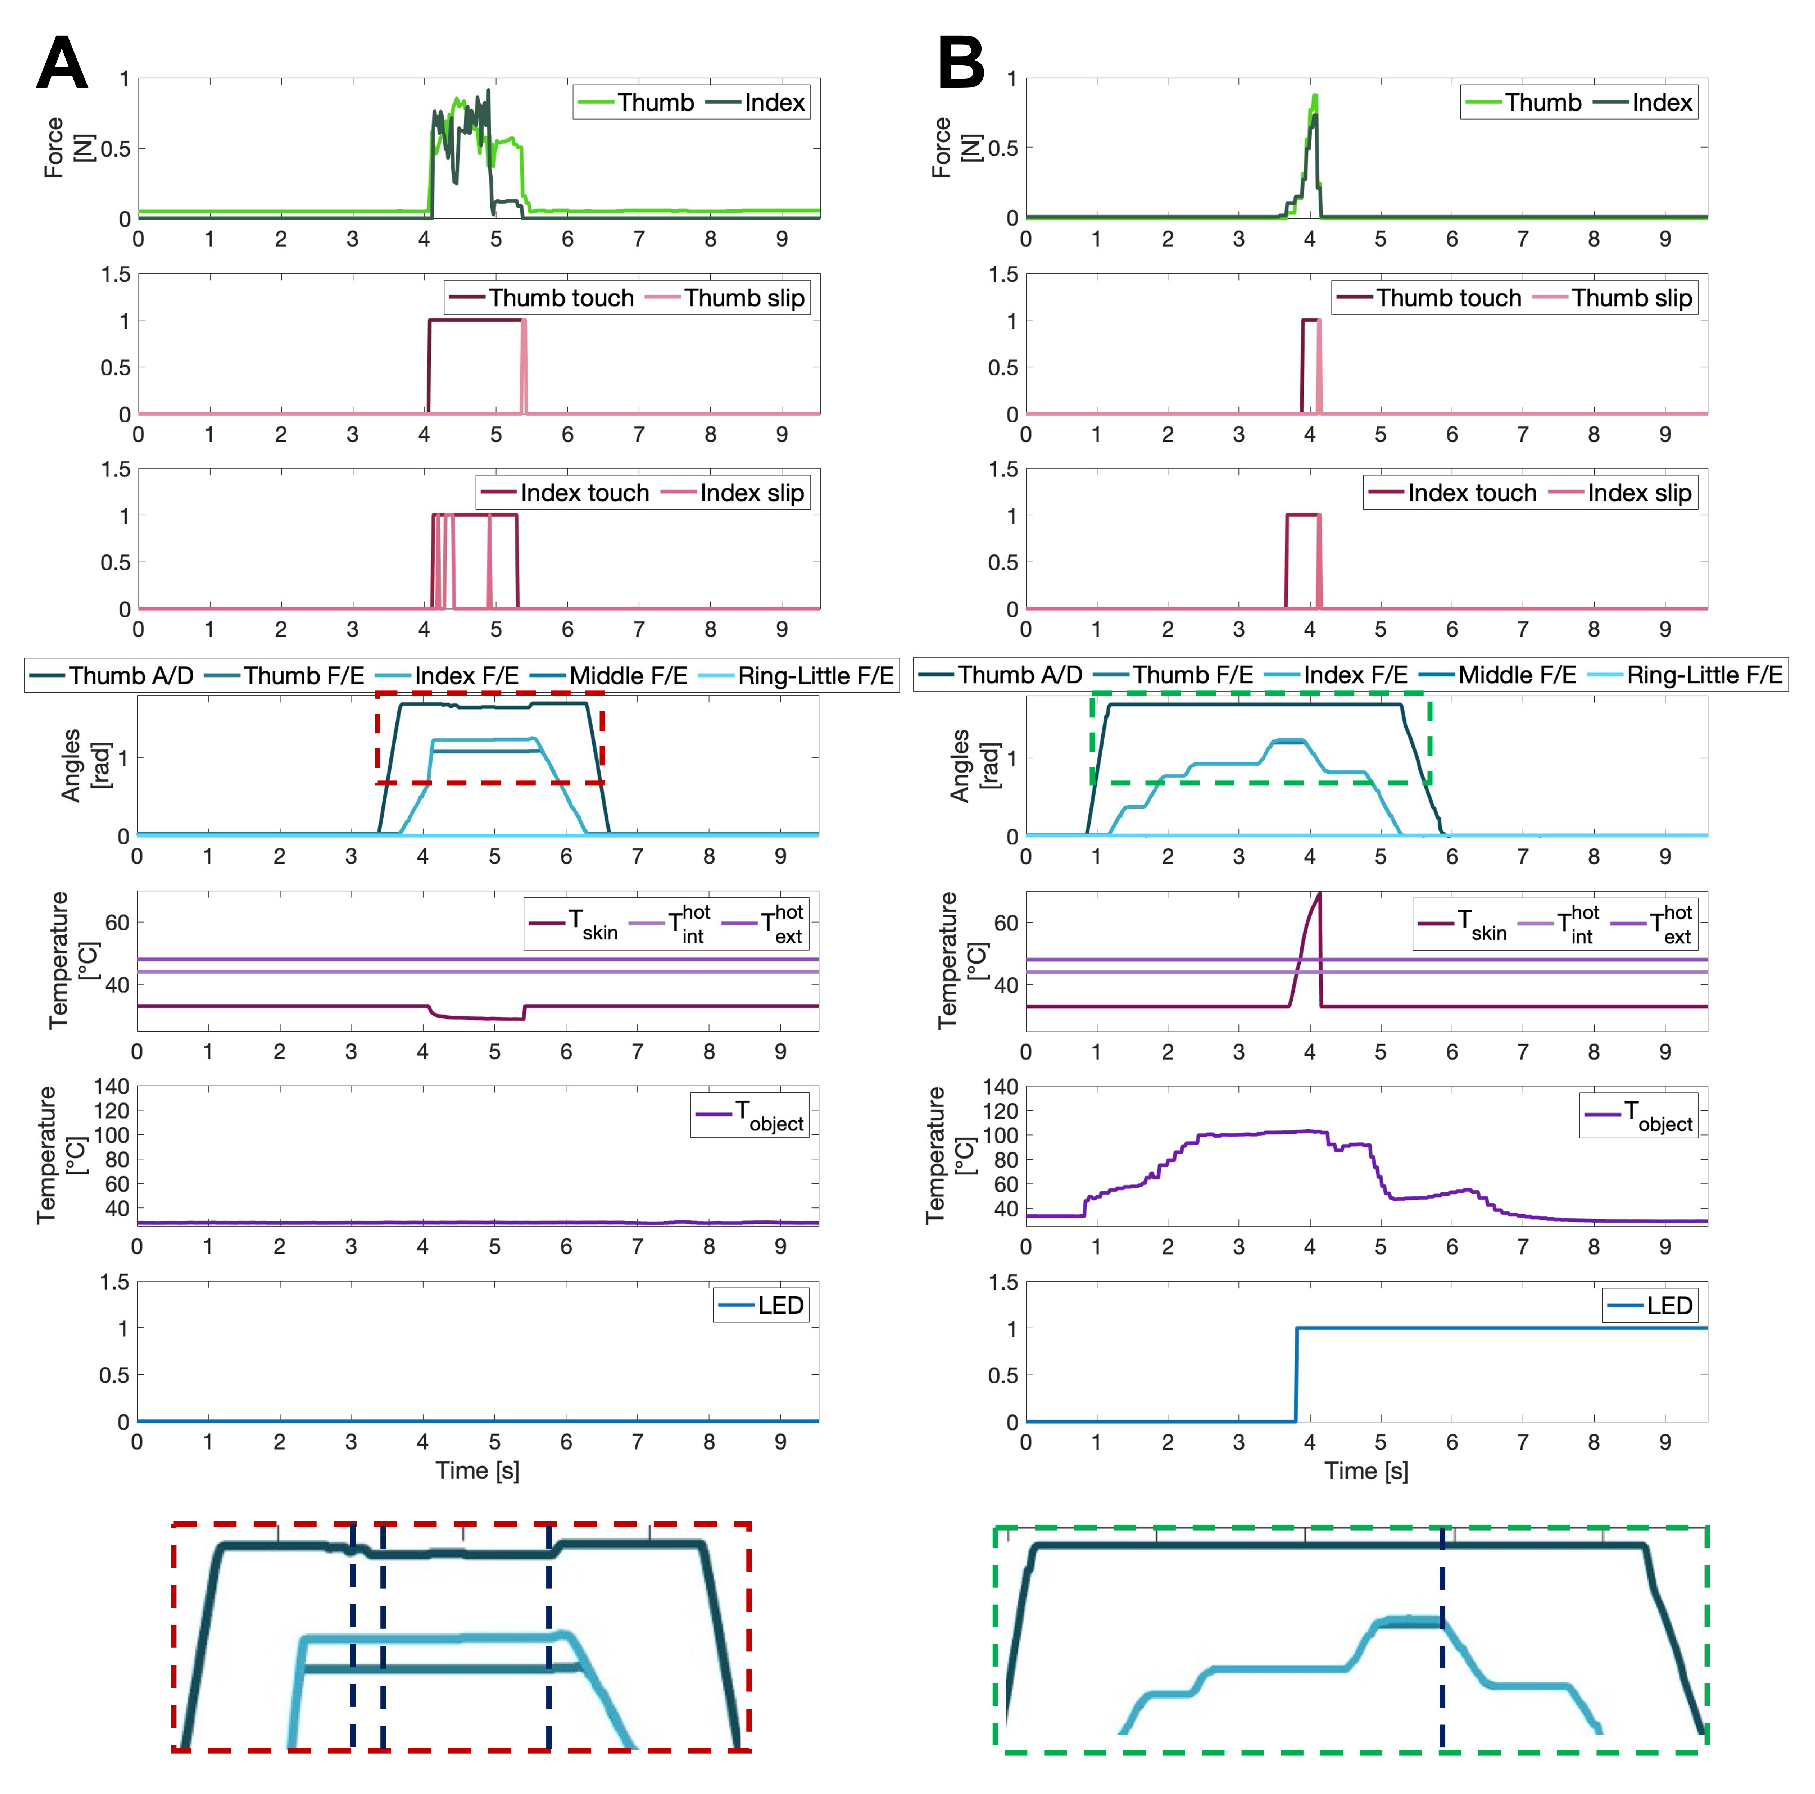
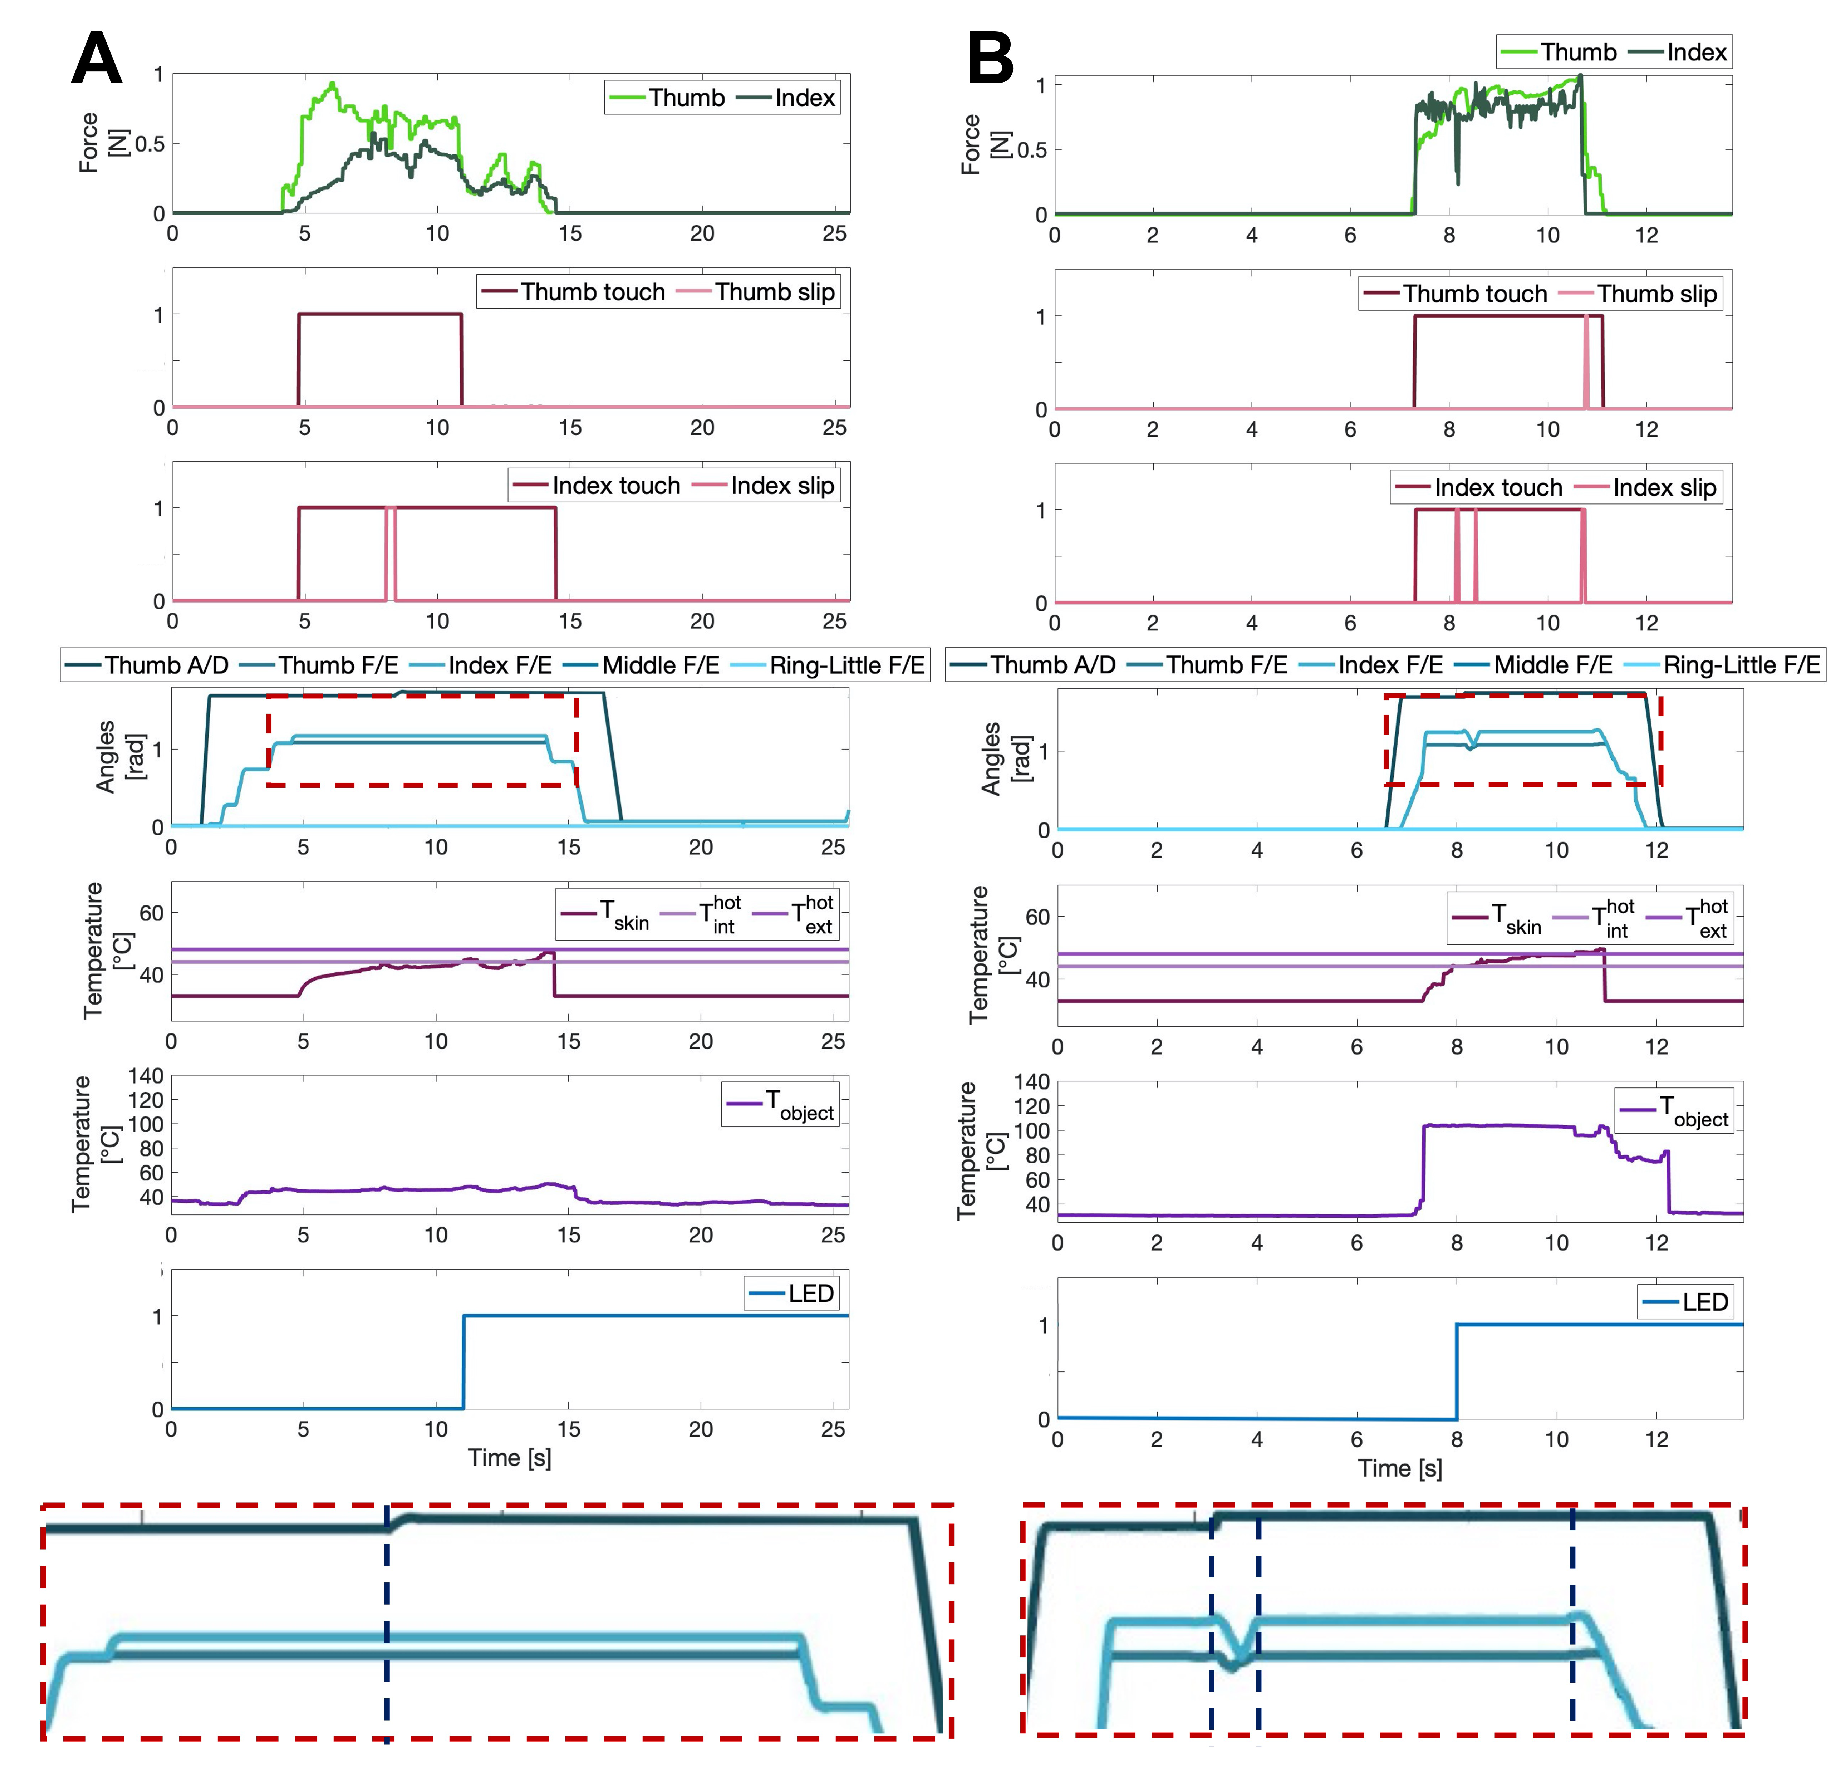
Prosthetic hand systems aim at restoring lost functionality in amputees. Manipulation and grasping are the main functions of the human hand, which are provided by skin sensitivity capable of protecting the hand from damage and perceiving the external environment. The present study aims at proposing a novel control strategy which improves the ability of the prosthetic hand to interact with the external environment by fostering the interaction of tactile (forces and slipping) and thermoceptive sensory information and by using them to guarantee grasp stability and improve user safety. The control strategy is based on force control with an internal position loop and slip detection, which is able to manage temperature information thanks to the interaction with objects at different temperatures. This architecture has been tested on a prosthetic hand, i.e., the IH2 Azzurra developed by Prensilia s.r.l, in different temperature and slippage conditions. The prosthetic system successfully performed the grasping tasks by managing the tactile and thermal information simultaneously. In particular, the system is able to guarantee a stable grasp during the execution of the tasks. Additionally, in the presence of an external stimulus (thermal or slippage), the prosthetic hand is able to react and always reacts to the stimulus instantaneously (reaction times ≤ 0.04 s, comparable to the one of the human being), regardless of its nature and in accordance with the control strategy. In this way, the prosthetic device is protected from damaging temperatures, the user is alerted of a dangerous situation and the stability of the grasp is restored in the event of a slip.
Keywords: prosthetic hand; force control; human-inspired control prosthetic hand; force control; human-inspired control