


Bridging Quantitative Scoring and Qualitative Grading: A Mapping Framework for Intelligent System Evaluation


 , and
Abstract
1. Introduction
2. Related Work
2.1. Qualitative Evaluation Methods
2.2. Quantitative Evaluation Methods
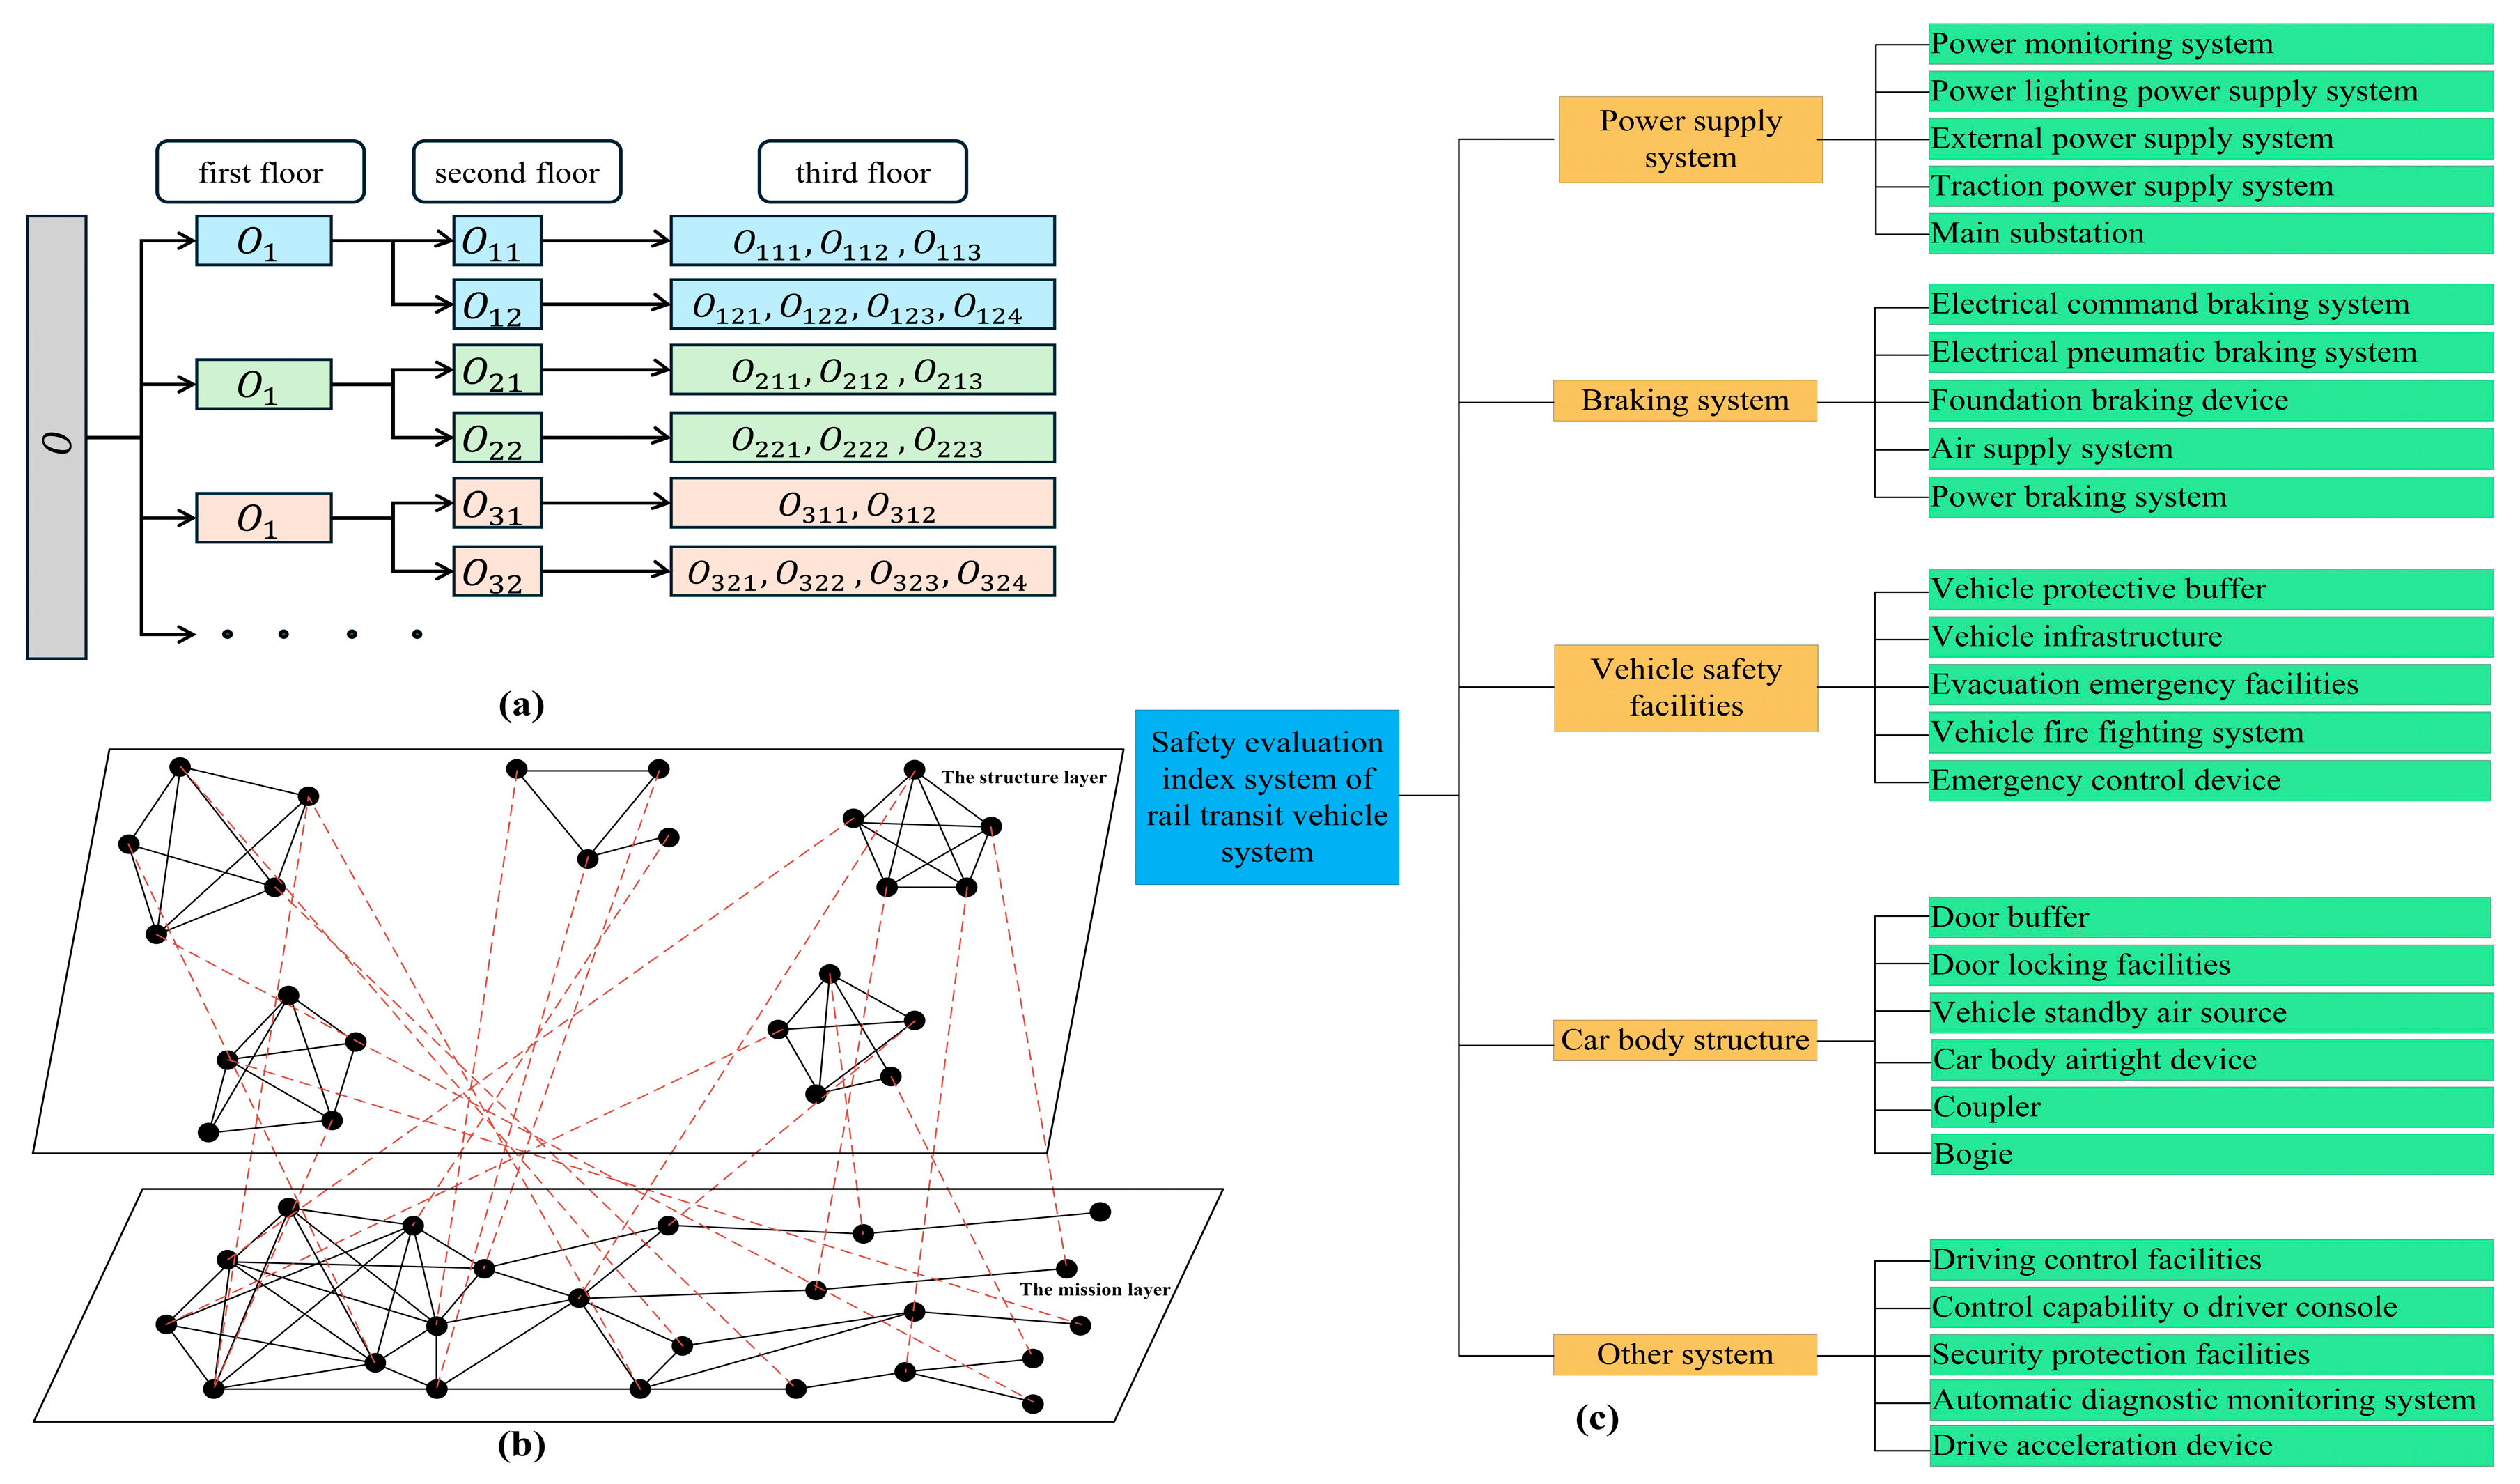
3. Proposed Framework
3.1. The Nonlinear Interval-Partitioned Module
3.2. The Quantitative–Qualitative Grade Mapping Module
3.3. The Dynamic Threshold Allocation Module
4. Experimental Validation
4.1. The Classical Mapping Case
4.1.1. Qualitative Method
4.1.2. Quantitative Method
4.2. Experiment Setup
4.3. Test 1: Score Threshold-Based Grading Test
4.4. Test 2: Grade Mapping Results Test
4.5. Test 3: Final Mapping Results Test
5. Conclusions
Author Contributions
Funding
Data Availability Statement
Conflicts of Interest
References
- Liu, L.; Lu, S.; Zhong, R.; Wu, B.; Yao, Y.; Zhang, Q.; Shi, W. Computing Systems for Autonomous Driving: State of the Art and Challenges. IEEE Internet Things J. 2021, 8, 6469–6486. [Google Scholar] [CrossRef] [Scilit]
- Manickam, P.; Mariappan, S.A.; Murugesan, S.M.; Hansda, S.; Kaushik, A.; Shinde, R.; Thipperudraswamy, S.P. Artificial intelligence (AI) and internet of medical things (IoMT) assisted biomedical systems for intelligent healthcare. Biosensors 2022, 12, 562. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Jie, C.; Sun, J.; Wang, G. From unmanned systems to autonomous intelligent systems. Engineering 2022, 12, 16–19. [Google Scholar]
- Hassan, K.; Thakur, A.K.; Singh, G.; Singh, J.; Gupta, L.R.; Singh, R. Application of artificial intelligence in aerospace engineering and its future directions: A systematic quantitative literature review. Arch. Comput. Methods Eng. 2024, 31, 4031–4086. [Google Scholar] [CrossRef] [Scilit]
- Quan, W.; Jia, L.; Zhang, Z.; Chen, C.; Wang, L. A Multi-Dimensional Dynamic Evaluation Method for the Intelligence of Unmanned Aerial Vehicle Swarm. In Proceedings of the 2023 IEEE International Conference on Unmanned Systems (ICUS), Hefei, China, 13–15 October 2023; pp. 731–737. [Google Scholar]
- Eley IV, T.C.; King, J.L.; Lyytinen, K.; Nickerson, J.V. SAE J3016 as a Learning Device for the Driving Automation Community: Technical, Socio-Technical, and Systemic Learning; SAE International: Warrendale, PA, USA, 2024. [Google Scholar]
- Huang, H.M.; Pavek, K.; Albus, J.; Messina, E. Autonomy levels for unmanned systems (ALFUS) framework: An update. In Proceedings of the SPIE 5804, Unmanned Ground Vehicle Technology VII, Orlando, FL, USA, 27 May 2005. [Google Scholar]
- Young, L.; Yetter, J.; Guynn, M. System analysis applied to autonomy: Application to high-altitude long-enduranceremotely operated aircraft. In Proceedings of the AIAA Infotech@Aerospace Conference, Arlington, VA, USA, 26–29 September 2005. [Google Scholar]
- Huang, H.; Zheng, X.; Yang, Y.; Liu, J.; Liu, W.; Wang, J. An integrated architecture for intelligence evaluation of automated vehicles. Accid. Anal. Prev. 2020, 145, 105681. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Wang, Y.; Li, M.; Huang, Y.; Chen, H. Intelligence Assessment of Automated Driving Systems Based on Driving Intelligence Quotient. In Proceedings of the 2021 5th CAA International Conference on Vehicular Control and Intelligence (CVCI), Tianjin, China, 29–31 October 2021; pp. 1–6. [Google Scholar]
- Zhang, P.; Zhu, B.; Zhao, J.; Fan, T.; Sun, Y. Safety evaluation method in multi-logical scenarios for automated vehicles based on naturalistic driving trajectory. Accid. Anal. Prev. 2023, 180, 106926. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Panagiotopoulos, I.E.; Karathanasopoulou, K.N.; Dimitrakopoulos, G.J. Risk Assessment in the Context of Dynamic Reconfiguration of Level of Driving Automation in Highly Automated Vehicles. In Proceedings of the 2021 International Conference on Computational Science and Computational Intelligence (CSCI), Las Vegas, NV, USA, 15–17 December 2021; pp. 1868–1873. [Google Scholar]
- Liu, J.Y.; Sun, L.N.; Zhao, Z.M. Unmanned Aerial Vehicle Cluster Distributed Combat Effectiveness Evaluation Based on DoDAF. In Proceedings of the 2022 International Conference on Autonomous Unmanned Systems (ICAUS 2022), Xi’an, China, 23–25 September 2022; Fu, W., Gu, M., Niu, Y., Eds.; Springer Nature: Singapore, 2023; Volume 1010, pp. 2264–2272. [Google Scholar]
- Han, Y.; Fang, D.; Zhang, H.; Li, Y. Evaluation of attack capability of UAV intelligent swarm based on AHP Fuzzy Evaluation. J. Phys. Conf. Ser. 2020, 1651, 012012. [Google Scholar] [CrossRef] [Scilit]
- Wang, S.; Du, Y.; Zhao, S.; Hao, J.; Gan, L. Research on the construction of weaponry indicator system and intelligent evaluation methods. Sci. Rep. 2023, 13, 19370. [Google Scholar] [CrossRef] [Scilit]
- Kong, J.; Zhu, H.; Pan, Y.; Li, Y.; Xiang, Y.; Hou, K. Comprehensive Evaluation of Secondary Equipment in Smart Substation Based on Real-time Information. Mech. Electr. Eng. Technol. 2023, 52, 221–226. [Google Scholar]
- He, L.; Yuan, D.; Ren, L.; Huang, M.; Zhang, W.; Tan, J. Evaluation Model Research of Coal Mine Intelligent Construction Based on FDEMATEL-ANP. Sustainability 2023, 15, 2238. [Google Scholar] [CrossRef] [Scilit]
- Clough, B.T. Metrics, Schmetrics! How The Heck Do You Determine A UAV’s Autonomy Anyway. NIST Spec. Publ. 2002, 990, 313–319. [Google Scholar]
- Sheridan, T.B.; VerPlank, W.L. Human and Computer Control of Undersea Teleoperators. In Human and Computer Control of Undersea Teleoperators; Institute of Tech Cambridge Man-Machine Systems Lab.: Boston, MA, USA, 1978. [Google Scholar]
- Gopinath, V. On Safe Collaborative Assembly with Large Industrial Robots; Linkopings Universitet: Linköping, Sweden, 2019. [Google Scholar] [CrossRef] [Scilit]
- Ma, S.; Zhang, H.; Yang, G. Target threat level assessment based on cloud model under fuzzy and uncertain conditions in air combat simulation. Aerosp. Sci. Technol. 2017, 67, 49–53. [Google Scholar] [CrossRef] [Scilit]
- Huang, H.-M. Autonomy levels for unmanned systems (ALFUS) framework: Safety and application issues. In Proceedings of the 2007 Workshop on Performance Metrics for Intelligent Systems (PerMIS ‘07), Washington, DC, USA, 28–30 August 2007; Association for Computing Machinery: New York, NY, USA, 2007; pp. 48–53. [Google Scholar]
- Peng, N.; Yin, J.; Wang, Q.; Huang, W. Research on Multi-Level and Multi-Dimensional Networked Effectiveness Evaluation Method of Aerospace Equipment. Comput. Simul. 2022, 39, 91–95. [Google Scholar]
- Zhang, Y.; Wang, X.; Zheng, L. Effectiveness Evaluation Method of the Unmanned Aerial Vehicle Swarm Considering Mission Process. In Proceedings of the 2021 5th Chinese Conference on Swarm Intelligence and Cooperative Control, Shenzhen, China, 19–22 November 2021; Lecture Notes in Electrical Engineering. Ren, Z., Wang, M., Hua, Y., Eds.; Springer: Singapore, 2023; Volume 934. [Google Scholar]
- Dong, S.; Yu, F.; Wang, K. Safety evaluation of rail transit vehicle system based on improved AHP-GA. PLoS ONE 2022, 17, e0273418. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Russo, R.d.F.S.M.; Camanho, R. Criteria in AHP: A Systematic Review of Literature. Procedia Comput. Sci. 2015, 55, 1123–1132. [Google Scholar] [CrossRef] [Scilit]
- Sun, Q.; Ge, X.; Liu, L.; Xu, X.; Zeng, Y.; Zhang, Y. Smart Grid Multi-Attribute Network Process Comprehensive Evaluation Method and Its Application. In Proceedings of the 2012 Asia-Pacific Power and Energy Engineering Conference, Shanghai, China, 7–8 April 2012; pp. 1–5. [Google Scholar]
- Xiao, B.; Zhao, X.; Dong, G. Summary and Prospect of Comprehensive Evaluation Methods of Power Quality. Power Gener. Technol. 2024, 45, 716–733. [Google Scholar]
- Han, Y.; Fang, D.; Zhang, H.; Li, Y. Efficiency evaluation of intelligent swarm based on AHP entropy weight method. J. Phys. Conf. Ser. 2020, 1693, 012072. [Google Scholar]
- Zhao, H.; Wang, Y.; Liu, X. The Evaluation of Smart City Construction Readiness in China Using CRITIC-G1 Method and the Bonferroni Operator. IEEE Access 2021, 9, 70024–70038. [Google Scholar] [CrossRef] [Scilit]
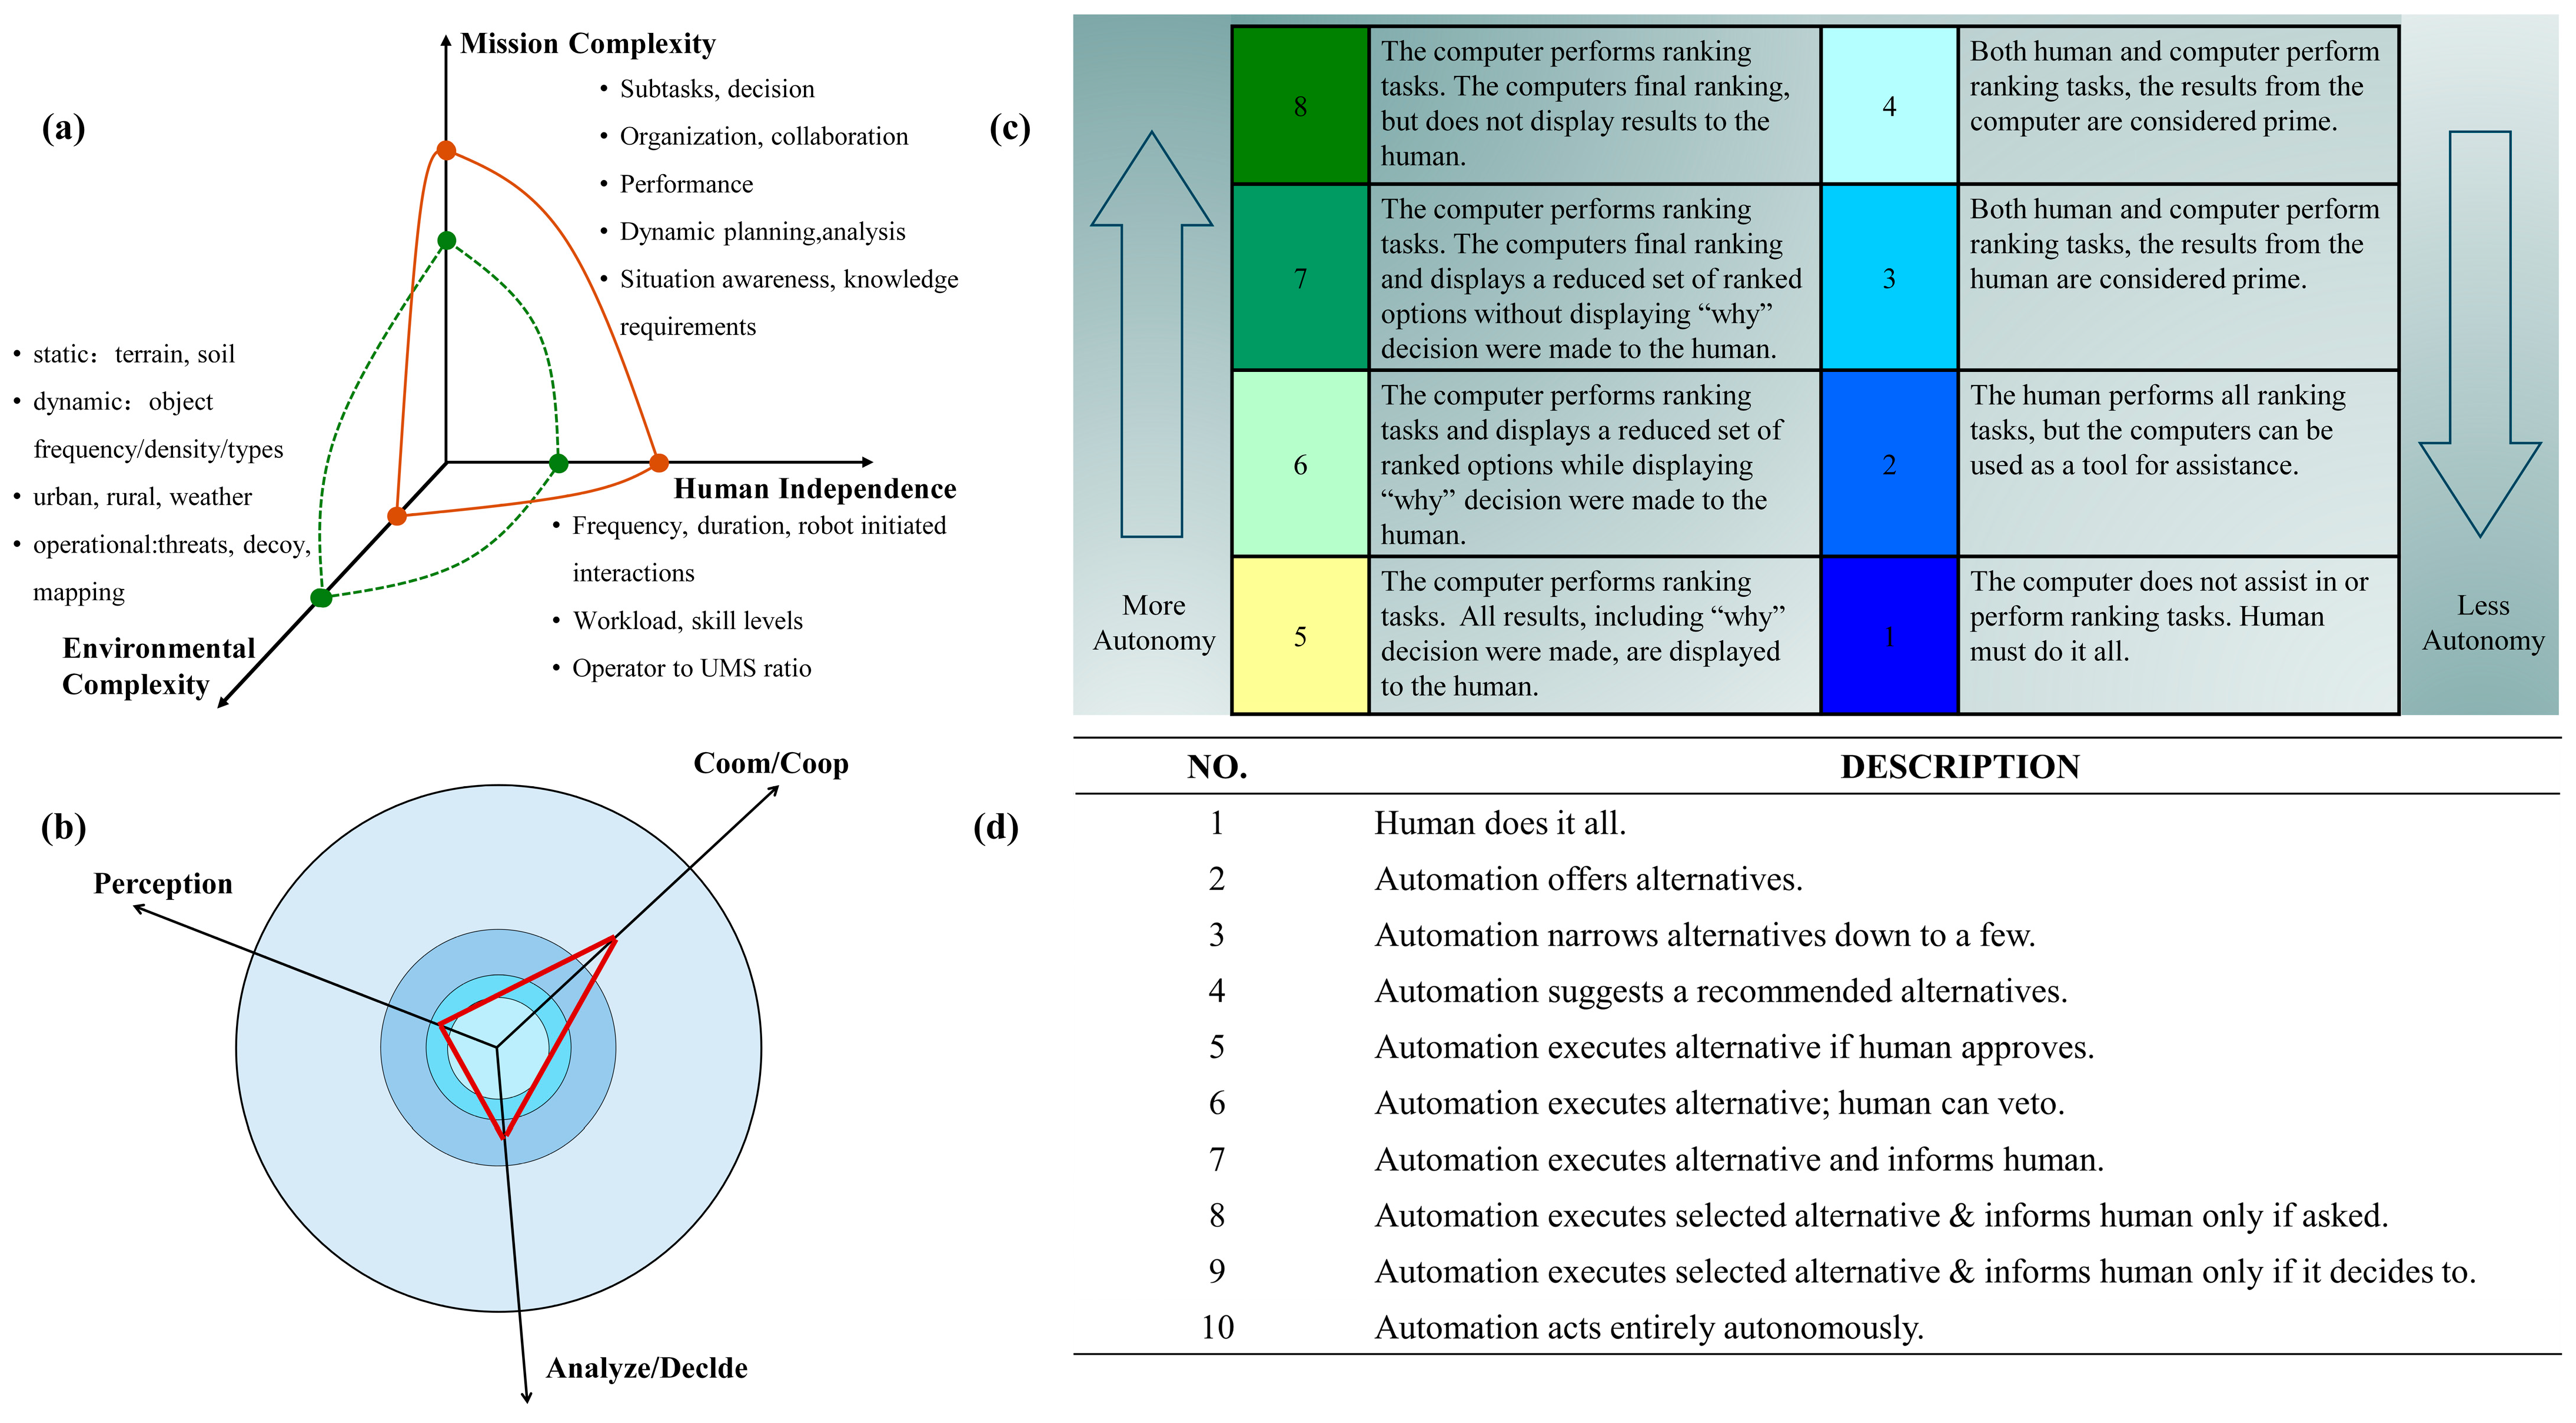
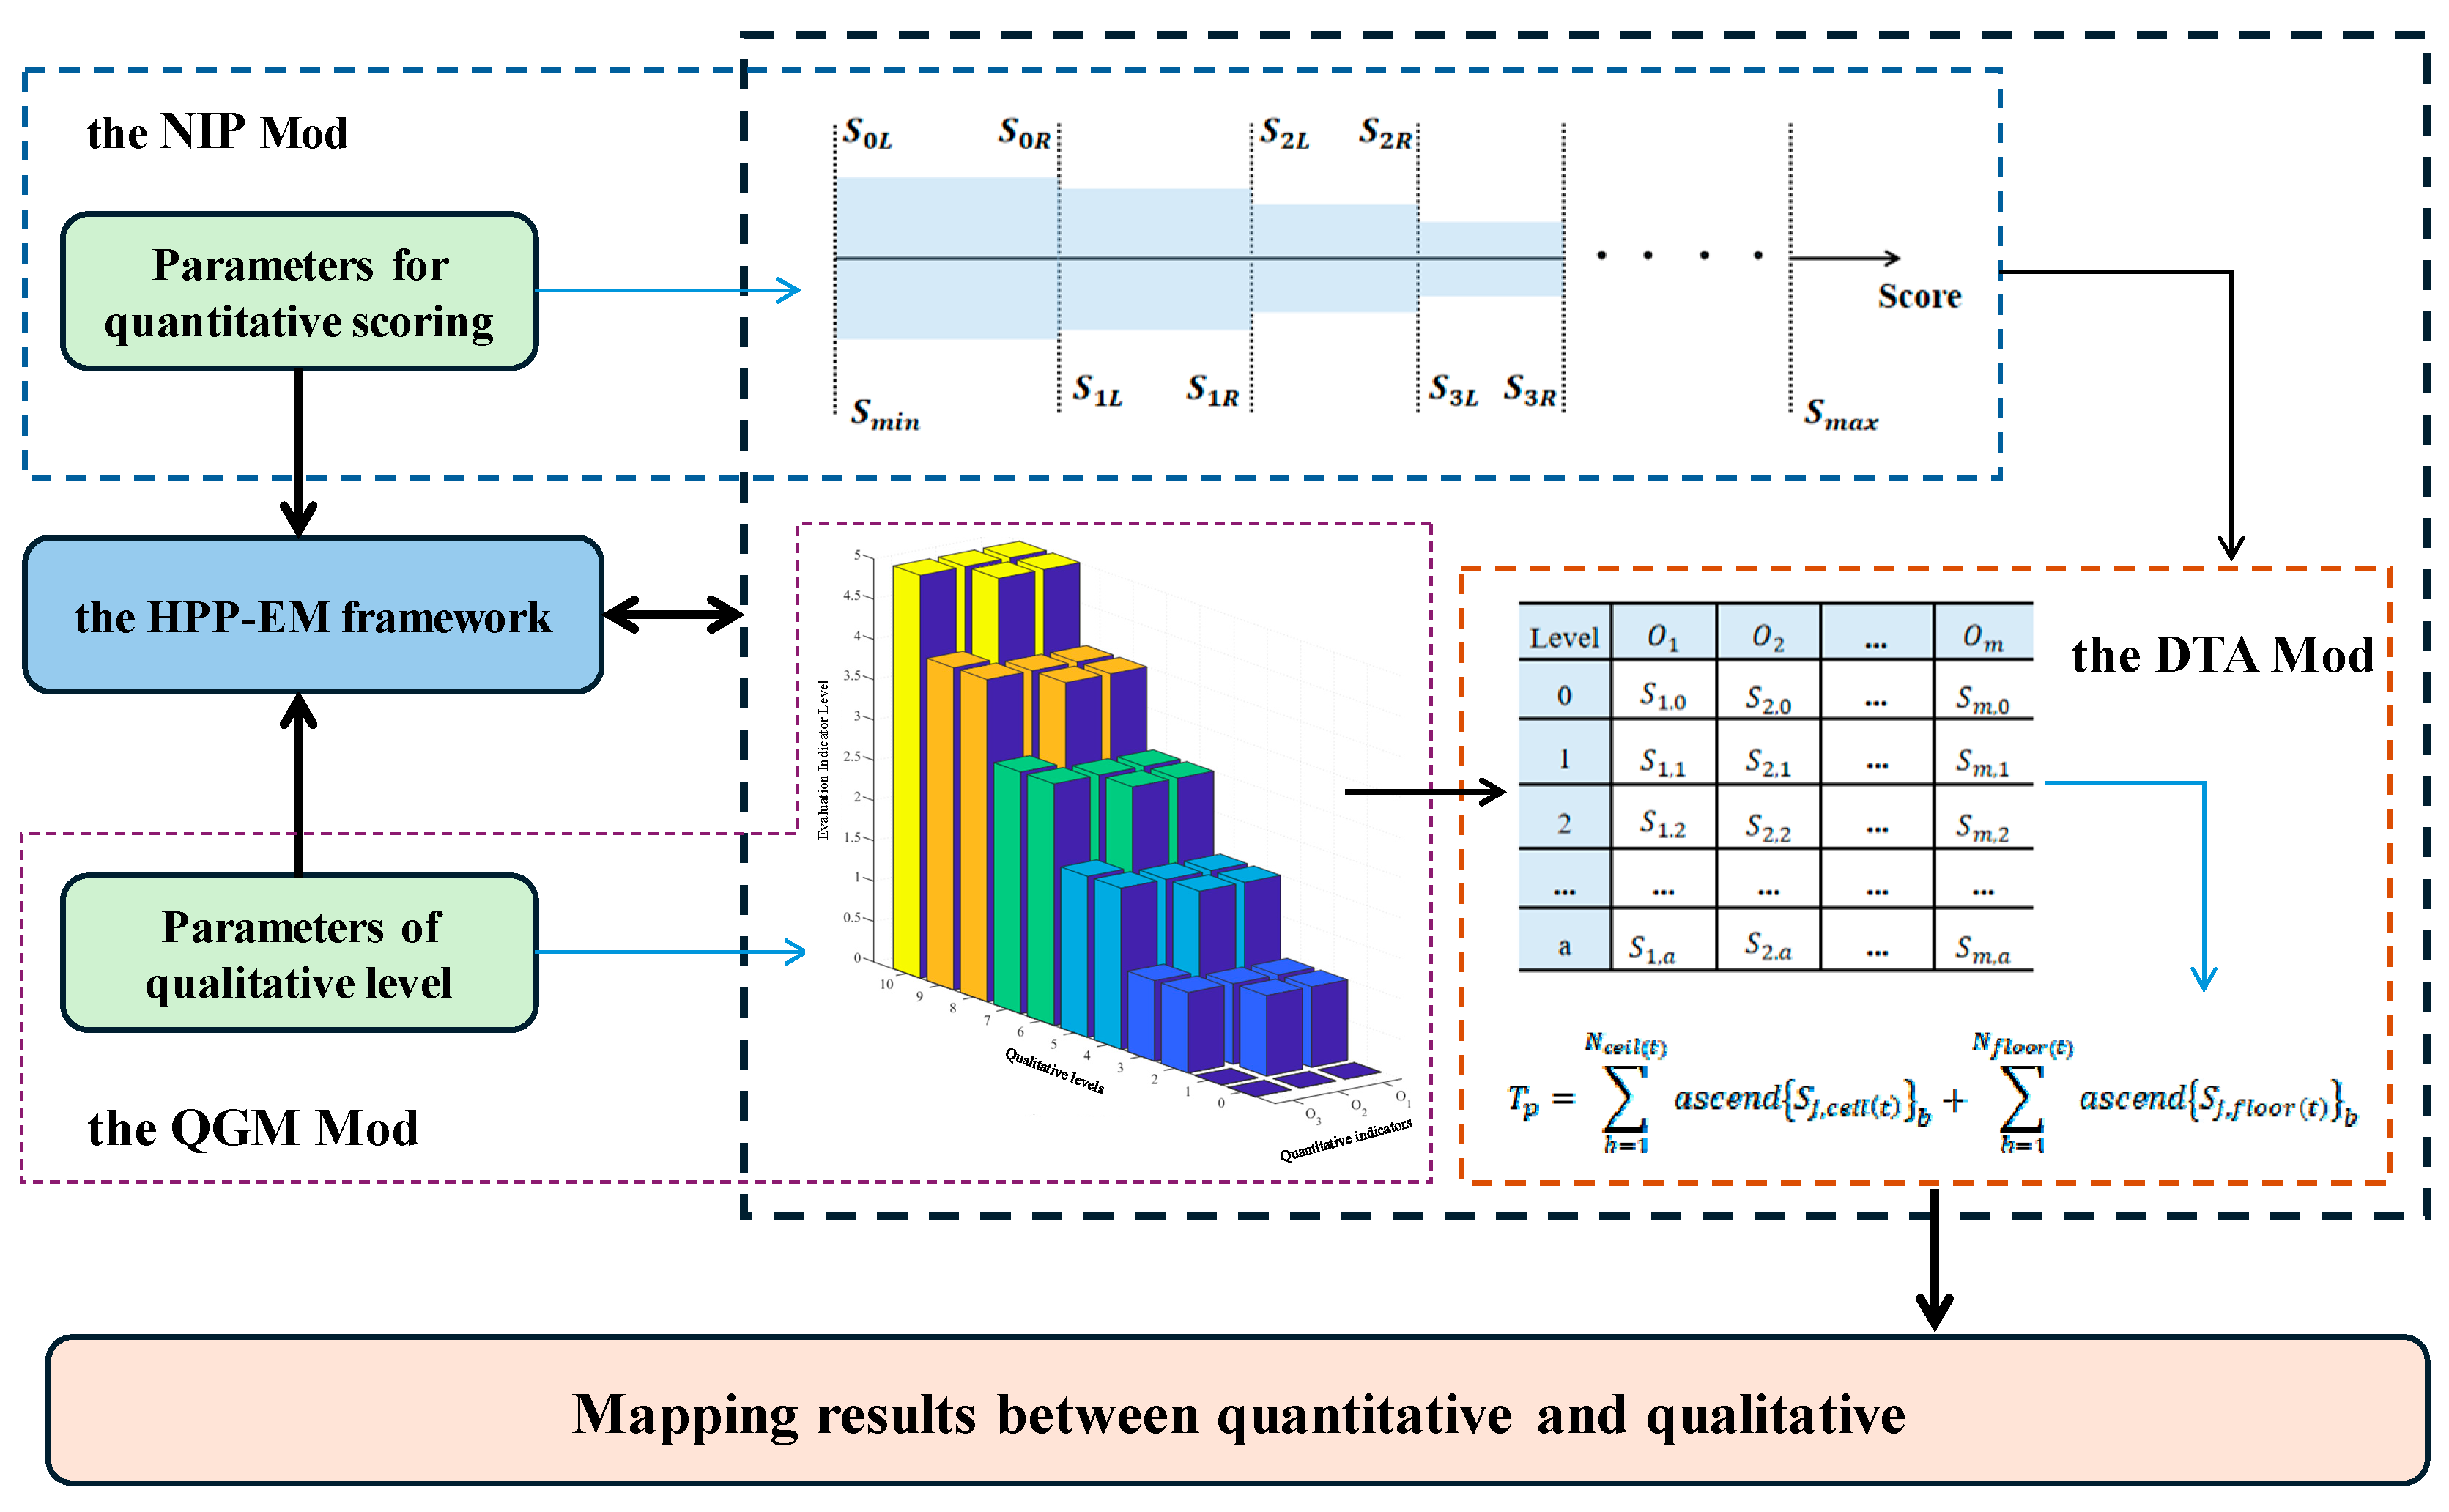
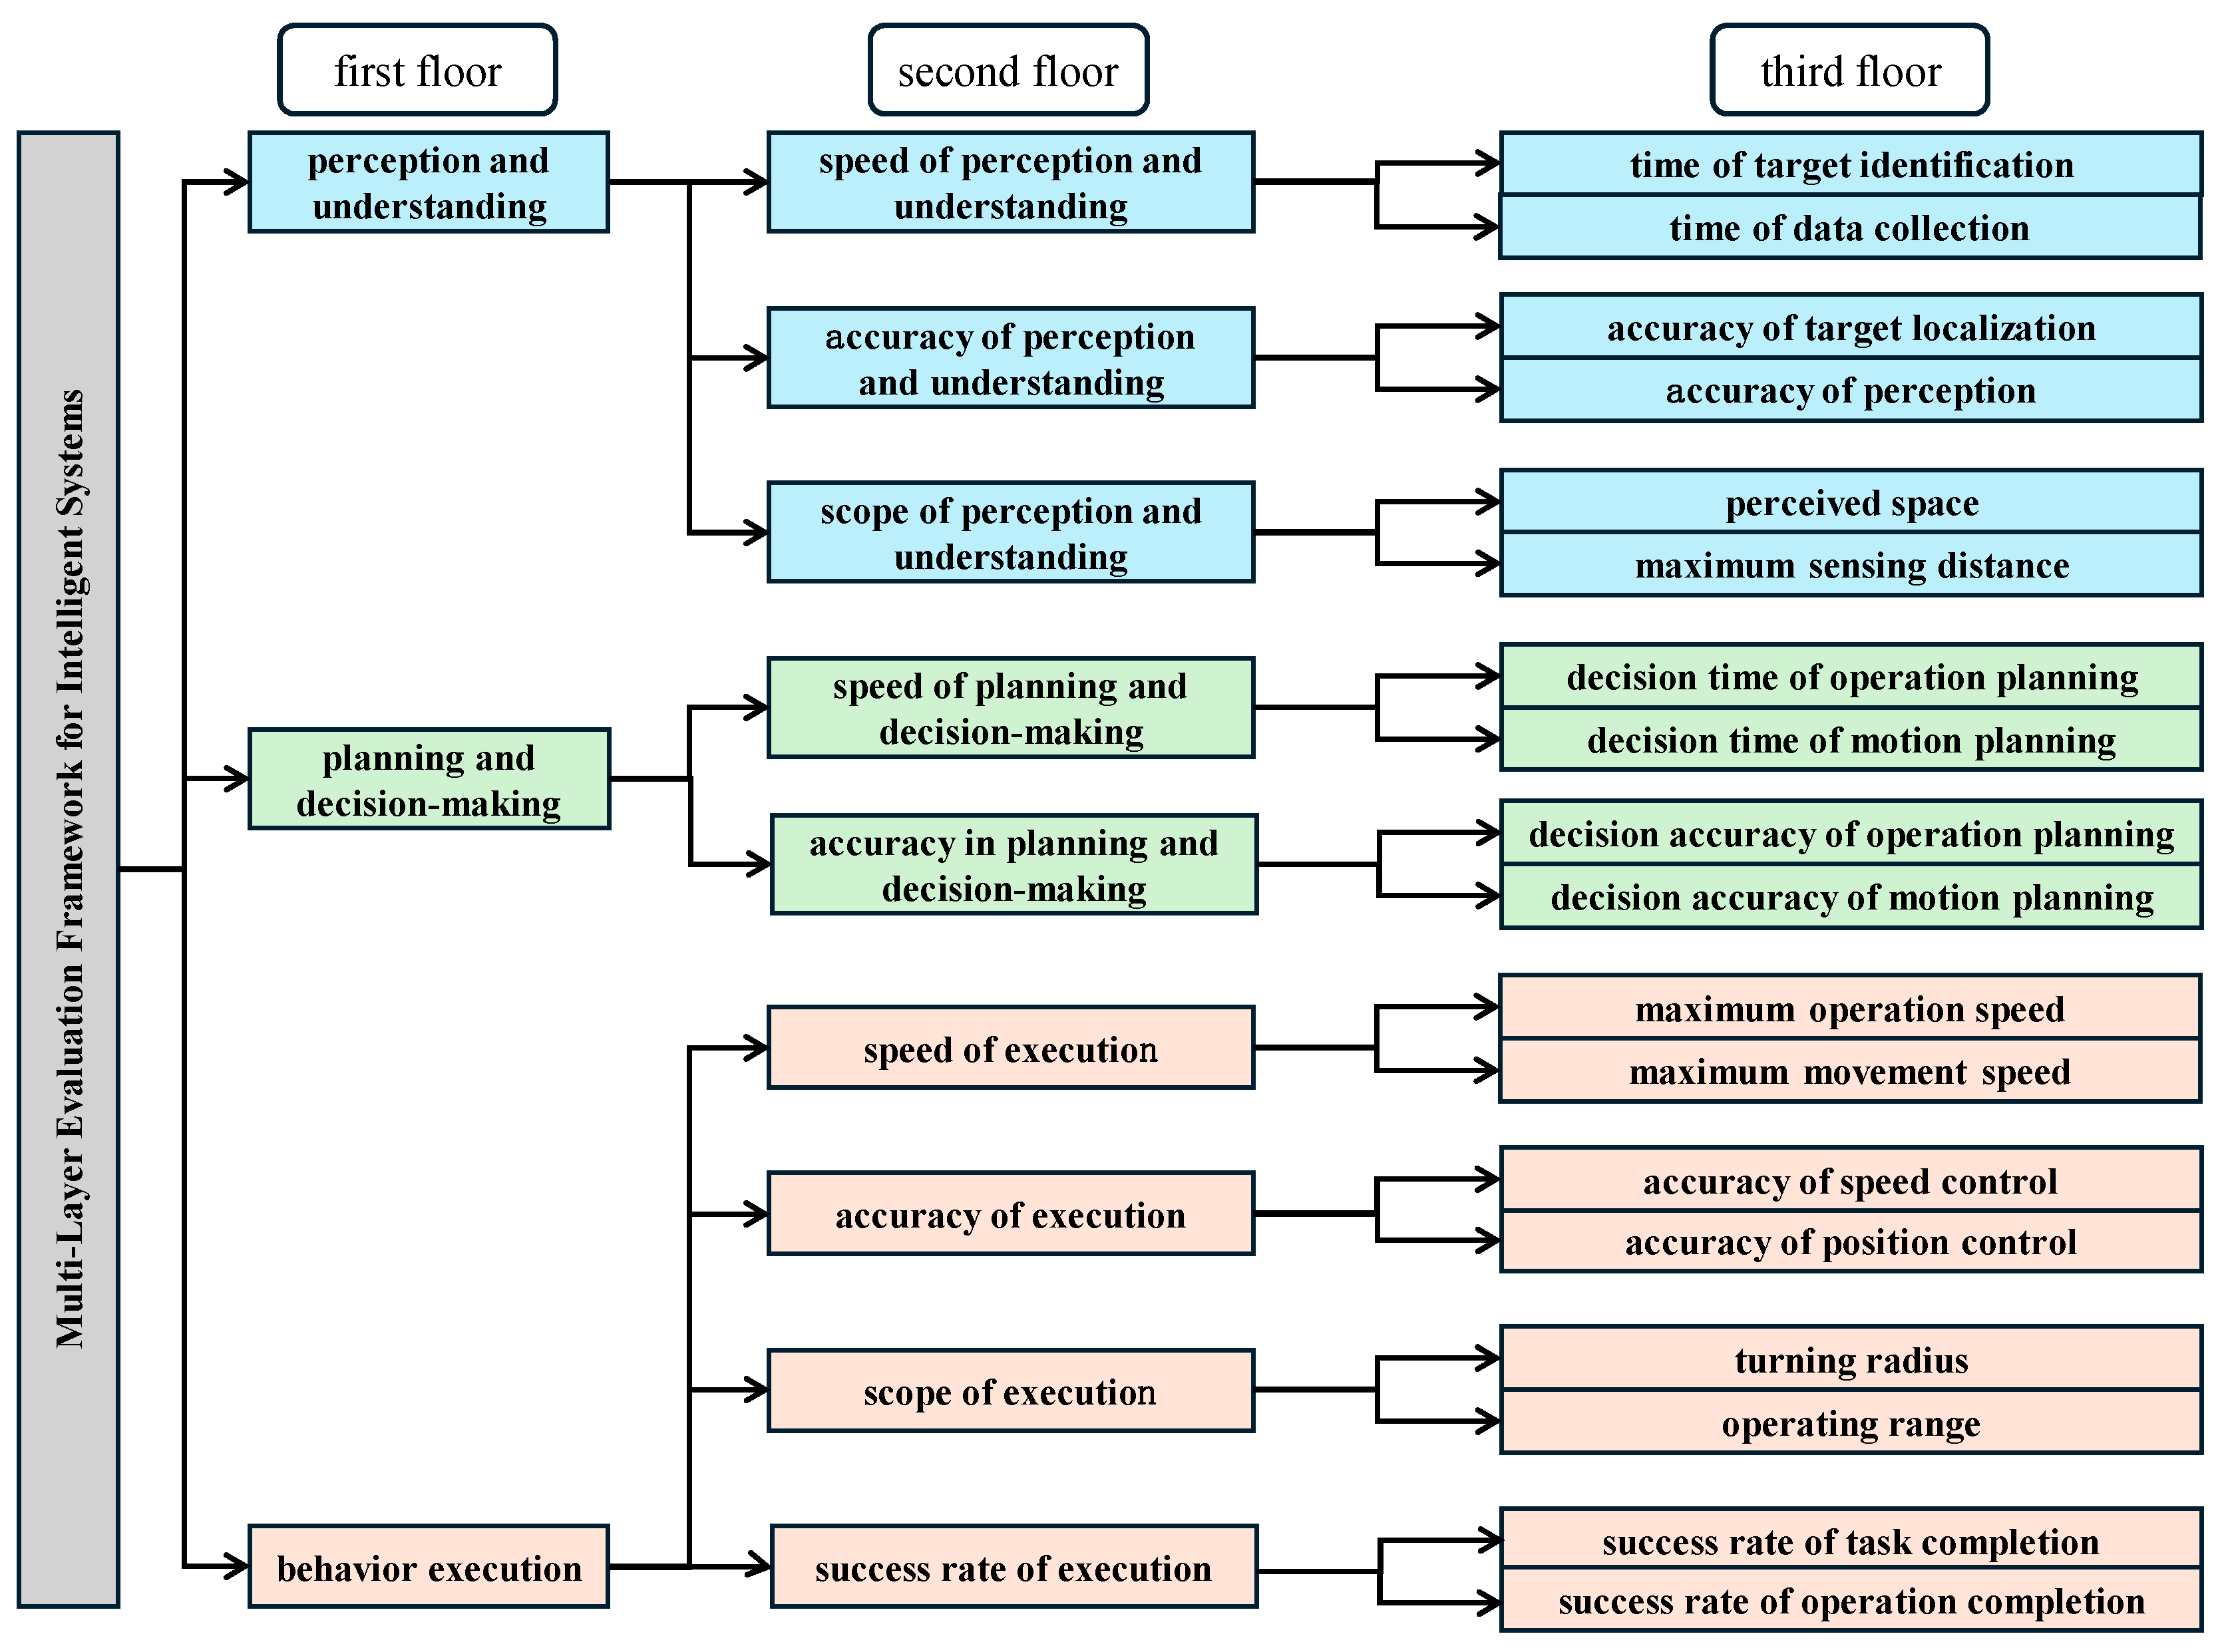

| Criteria | ALFUS | SAE J3016 | NASA SMART |
|---|---|---|---|
| Target Domain | General unmanned systems (land, air, space) | Road-based autonomous vehicles | Spacecraft automation |
| Evaluation Scope | Multi-dimensional: mission, environment, human independence | Driving tasks and human involvement levels (L0–L5) | Command sequence automation |
| Level Granularity | 10-level detailed autonomy scale | 6 fixed levels | Coarse categorical stages |
| Aerospace Suitability | High—supports dynamic, uncertain extraterrestrial contexts | Not applicable | Partial—lacks scoring flexibility |
| Integration with Quantitative Models | Compatible with score-based, weighted mapping frameworks | Static framework, not modular | Not structured for multi-indicator evaluation |
| Level | ALFUS Qualitative Description |
|---|---|
| Level 1 | remote control |
| Level 2 | remote control/vehicle status recognition |
| Level 3 | pre-task planning or post-order traversal |
| Level 4 | online processing of sensor images |
| Level 5 | simple obstacle detection and avoidance |
| Level 6 | simple obstacle detection and avoidance, terrain analysis |
| Level 7 | moving target detection for autonomous driving in road and off-road environments |
| Level 8 | collaborative operations, convoy, intersection navigation, and transportation following |
| Level 9 | collaborative operation, recognition of traffic signs and signals, approaching human-level driving capabilities |
| Level 10 | achieving or surpassing full autonomous capabilities at or beyond human performance levels |
| Level | Perception and Understanding | Planning and Decision-Making | Behavioral Execution |
|---|---|---|---|
| Level 0 | 0.00 | 0.00 | 0.56 |
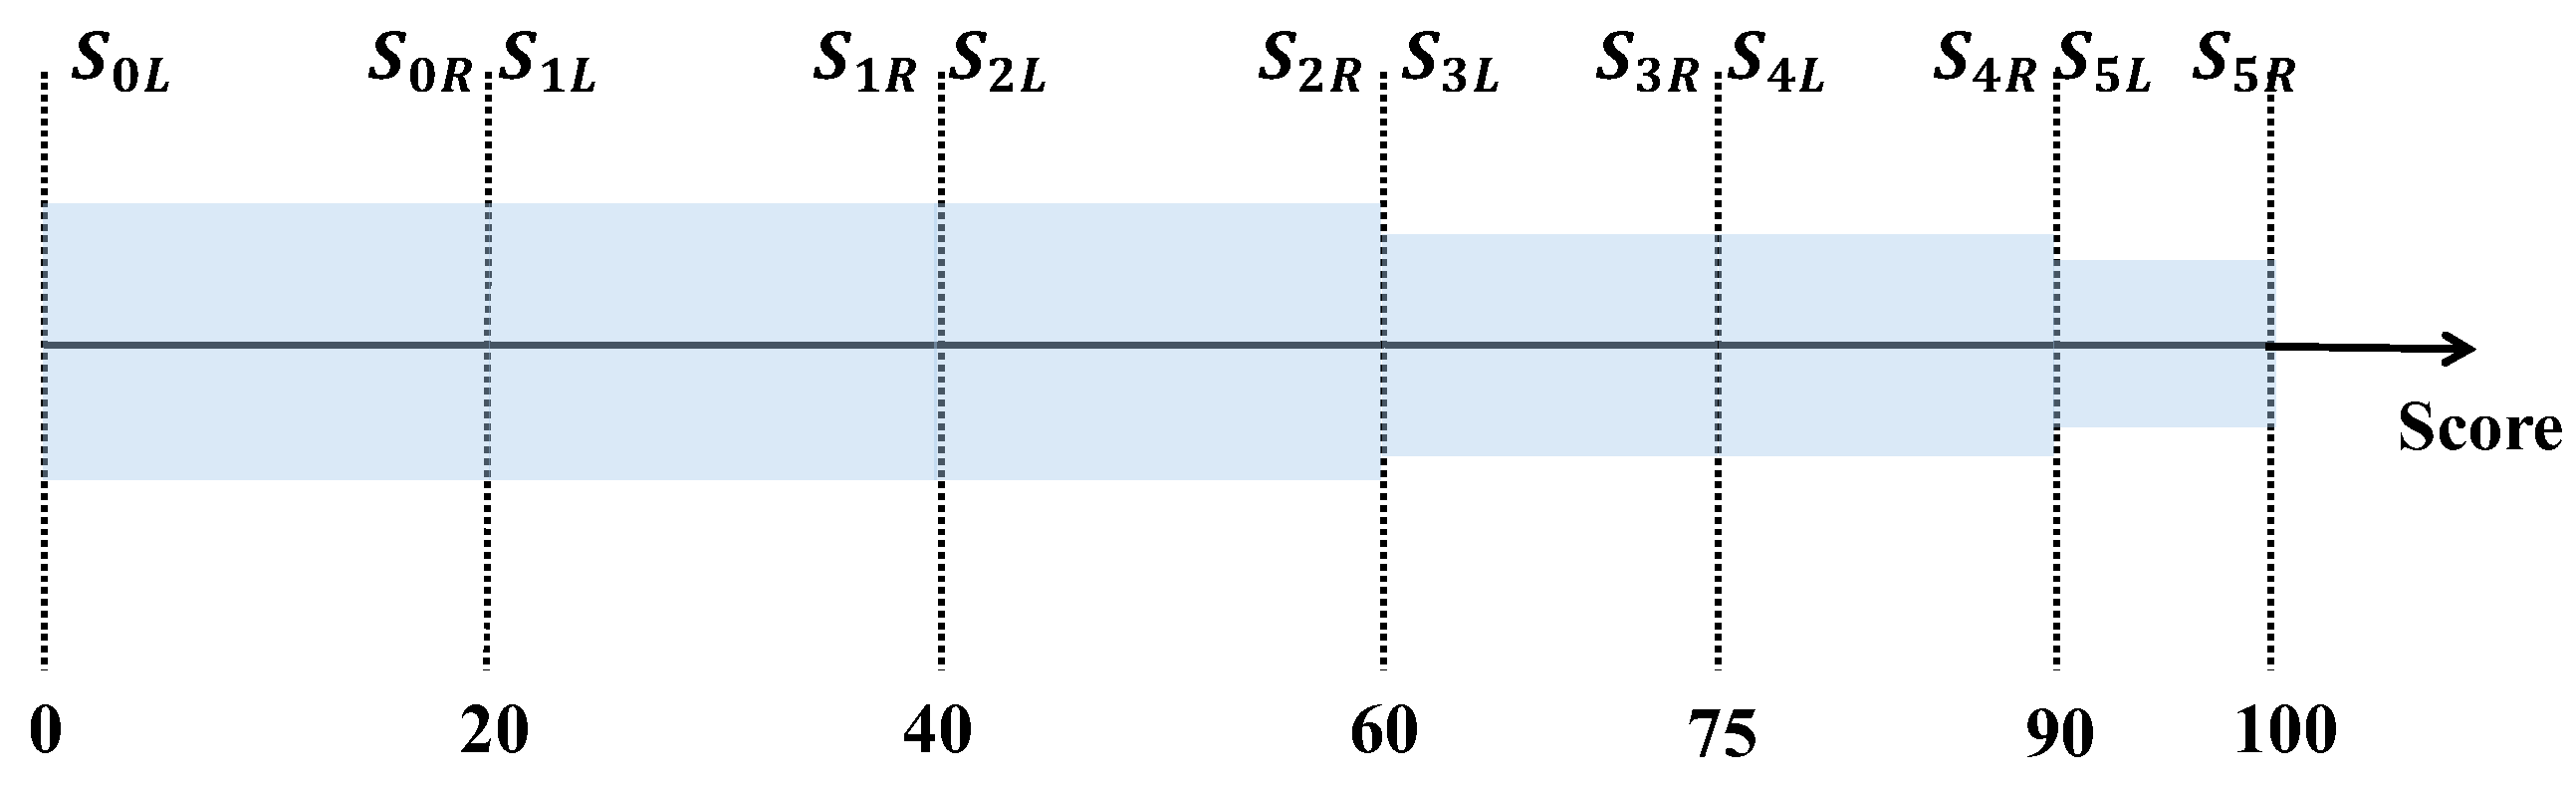
| Level 1 | 20.00 | 18.68 | 21.68 |
| Level 2 | 40.00 | 37.80 | 42.79 |
| Level 3 | 60.00 | 57.77 | 62.83 |
| Level 4 | 75.00 | 72.27 | 78.46 |
| Level 5 | 90.00 | 87.90 | 92.65 |
| ALFUS Level | Quantitative Indicators | ALFUS Qualitative Description | |||
|---|---|---|---|---|---|
| Perception and Understanding (≥) | Planning and Decision-Making (≥) | Behavioral Execution (≥) | Total Score (≥) | ||
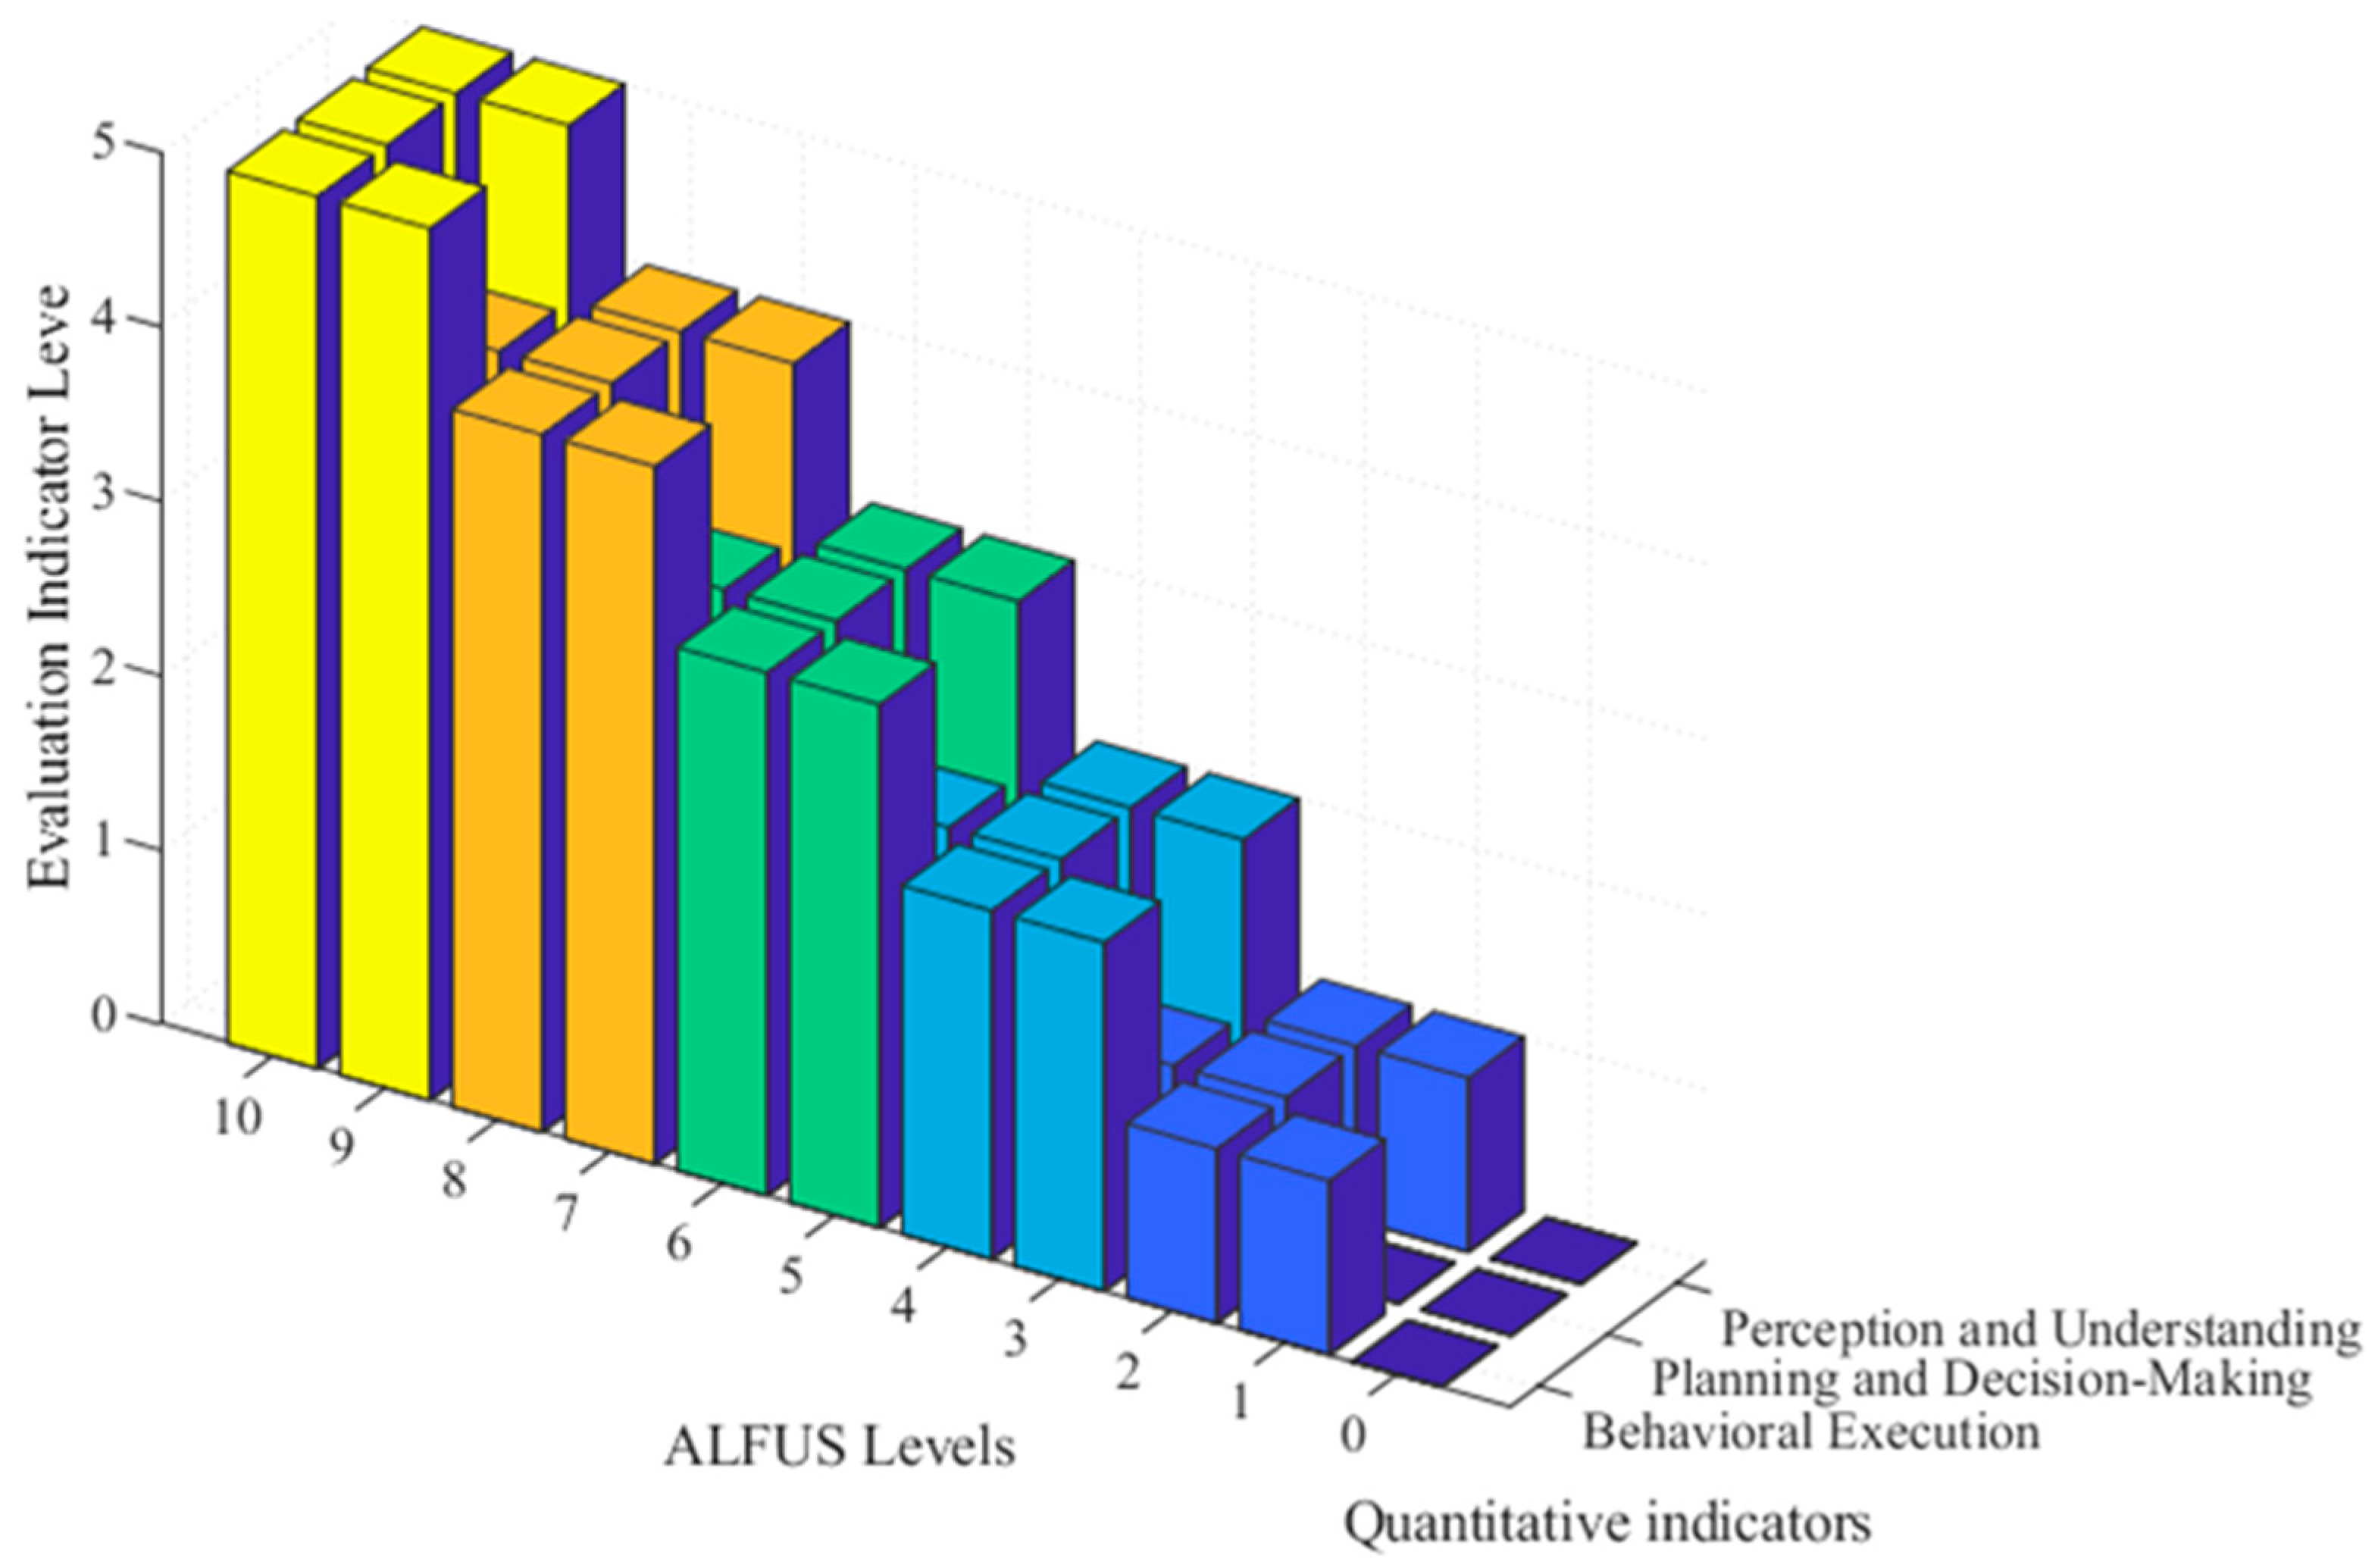
| Level 0 | 0.00 | 0.00 | 0.56 | 0.56 | \ |
| Level 1 | 20.00 | 0.00 | 21.68 | 38.68 | remote control |
| Level 2 | 20.00 | 18.68 | 21.68 | 60.36 | remote control/vehicle state recognition |
| Level 3 | 40.00 | 18.68 | 42.79 | 96.48 | pre-mission planning or post-order traversal |
| Level 4 | 40.00 | 37.80 | 42.79 | 120.59 | online processing of sensor image |
| Level 5 | 60.00 | 37.80 | 62.83 | 155.57 | simple obstacle detection and avoidance |
| Level 6 | 60.00 | 57.77 | 62.83 | 180.6 | complex obstacle detection and avoidance, terrain analysis |
| Level 7 | 75.00 | 57.77 | 78.46 | 205.04 | autonomous driving in road or off-road environments with moving target detection |
| Level 8 | 75.00 | 72.27 | 78.46 | 225.73 | collaborative operations, convoy escort, intersection navigation, and transport following |
| Level 9 | 90.00 | 72.27 | 92.65 | 250.17 | collaborative operation, recognition of traffic signs and signals, approaching human-level driving capabilities |
| Level 10 | 90.00 | 87.90 | 92.65 | 270.55 | achieving or exceeding human-level fully autonomous capabilities |
| Evaluation Dimension | Linear Mapping | Entropy Weighting | HPP-EM (Proposed) |
|---|---|---|---|
| Weight heterogeneity considered | No | Yes | Yes |
| Structural information utilized | No | No | Yes (Hierarchical Path Modeling) |
| Expert classification consistency | |||
| Score achieved (total) | 224.57 | ||
| Mapped ALFUS level | Level 6 | Level 6–7 | Level 7 (expert-confirmed match) |
| Robustness under uneven weights | Low | Medium | High |
| Applicable scenarios | Simple indicator sets | Weight-sensitive systems | Complex, hierarchical systems |
| Summary of strengths | Simple and fast | Incorporates entropy | High interpretability and accuracy |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2025 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).
Share and Cite
Hao, R.; Shi, M.; Hu, Y.; Wei, C.; Feng, L.; Wang, D.; Yuan, L. Bridging Quantitative Scoring and Qualitative Grading: A Mapping Framework for Intelligent System Evaluation. Electronics 2025, 14, 2470. https://doi.org/10.3390/electronics14122470
Hao R, Shi M, Hu Y, Wei C, Feng L, Wang D, Yuan L. Bridging Quantitative Scoring and Qualitative Grading: A Mapping Framework for Intelligent System Evaluation. Electronics. 2025; 14(12):2470. https://doi.org/10.3390/electronics14122470
Chicago/Turabian StyleHao, Renjian, Mujia Shi, Yong Hu, Chunling Wei, Lihang Feng, Dong Wang, and Li Yuan. 2025. "Bridging Quantitative Scoring and Qualitative Grading: A Mapping Framework for Intelligent System Evaluation" Electronics 14, no. 12: 2470. https://doi.org/10.3390/electronics14122470
APA StyleHao, R., Shi, M., Hu, Y., Wei, C., Feng, L., Wang, D., & Yuan, L. (2025). Bridging Quantitative Scoring and Qualitative Grading: A Mapping Framework for Intelligent System Evaluation. Electronics, 14(12), 2470. https://doi.org/10.3390/electronics14122470



