Article

Vehicle Lateral Control Based on Dynamic Boundary of Phase Plane Based on Tire Characteristics

School of Vehicle and Energy, Yanshan University, Qinhuangdao 066000, China
*
Author to whom correspondence should be addressed.
Electronics 2023, 12(24), 5012; https://doi.org/10.3390/electronics12245012

Submission received: 23 October 2023 / Revised: 7 December 2023 / Accepted: 12 December 2023 / Published: 15 December 2023
(This article belongs to the Section Electrical and Autonomous Vehicles)

Abstract

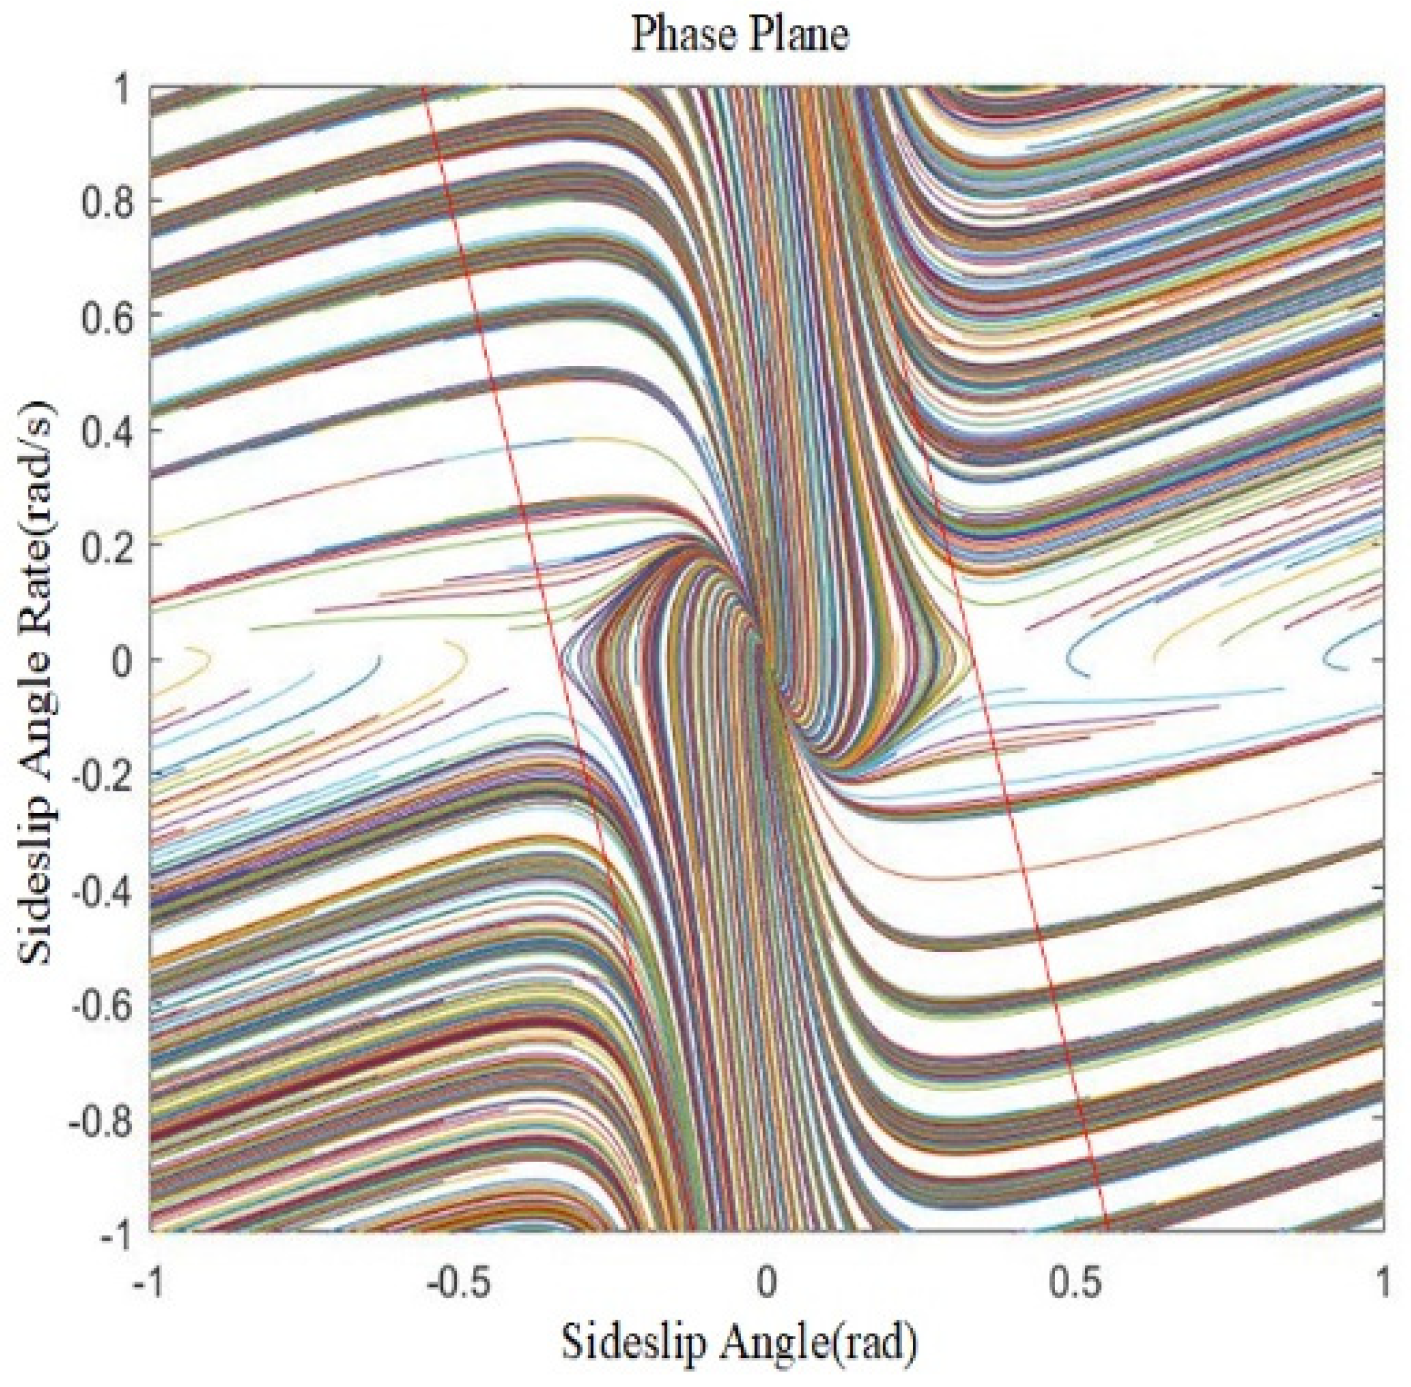
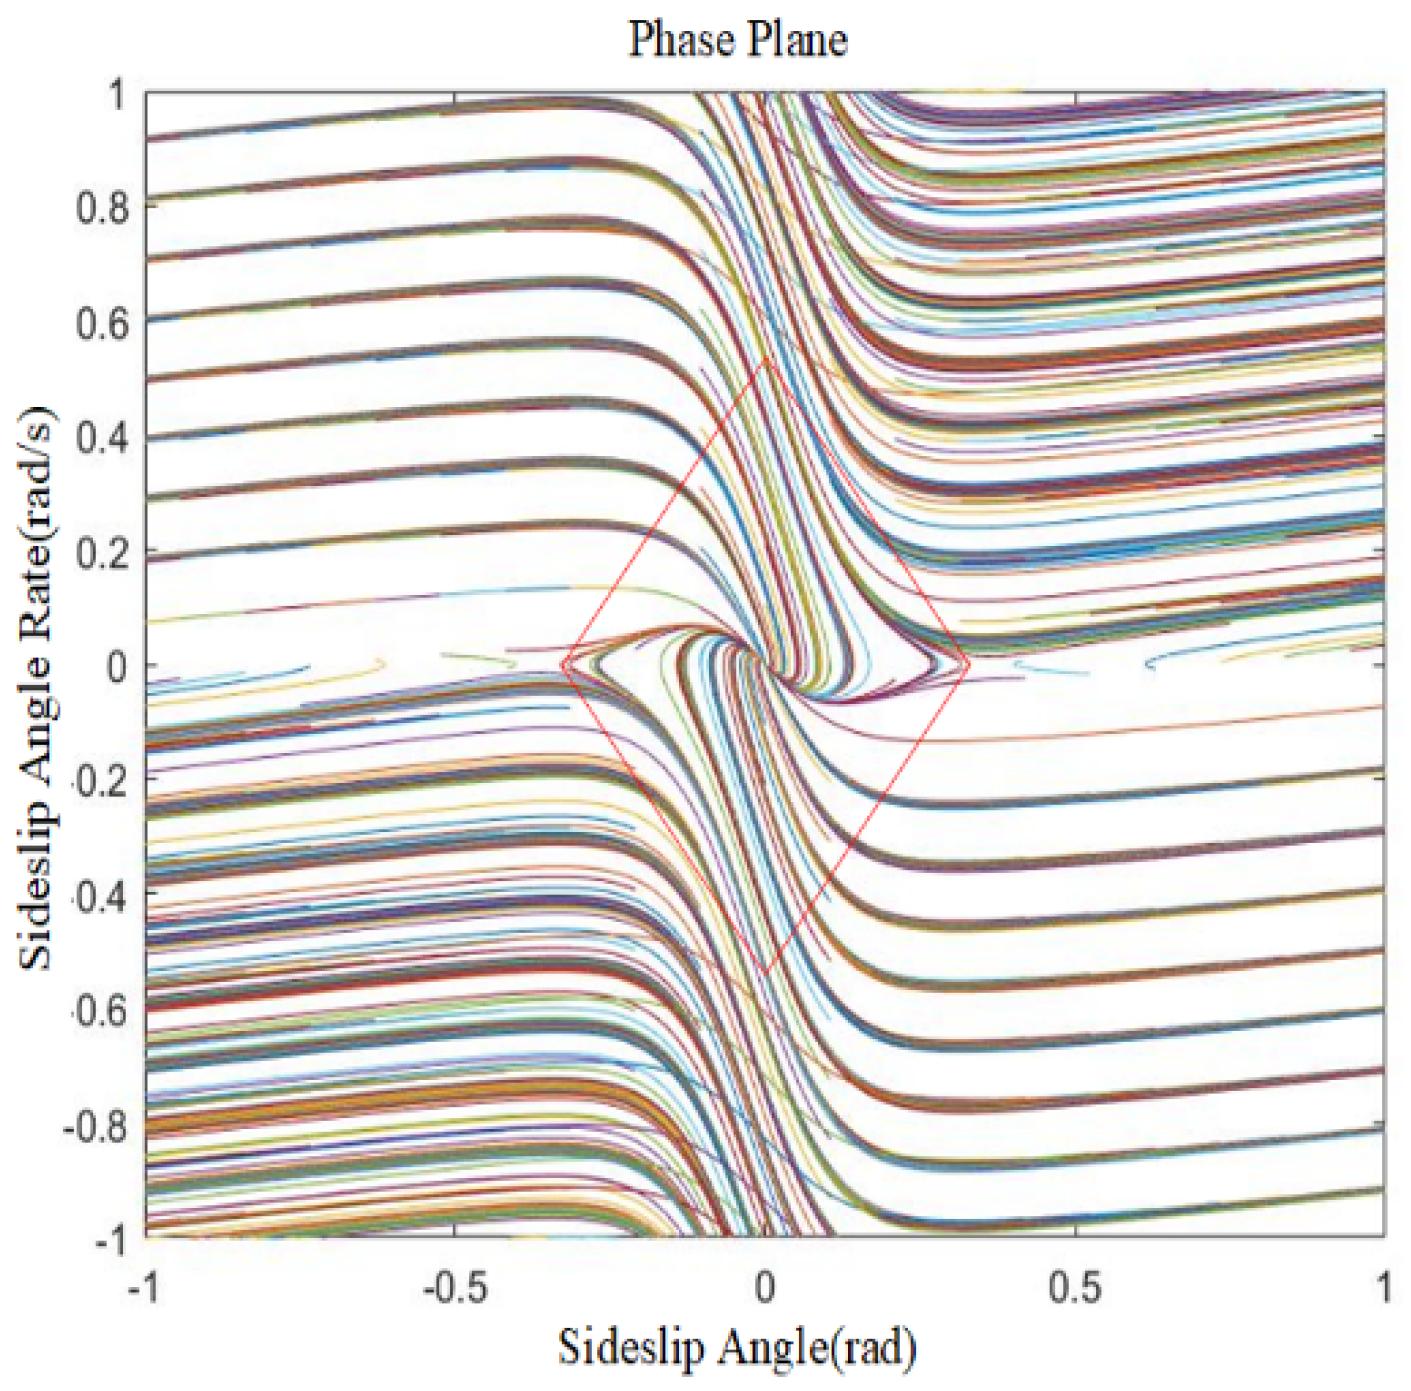
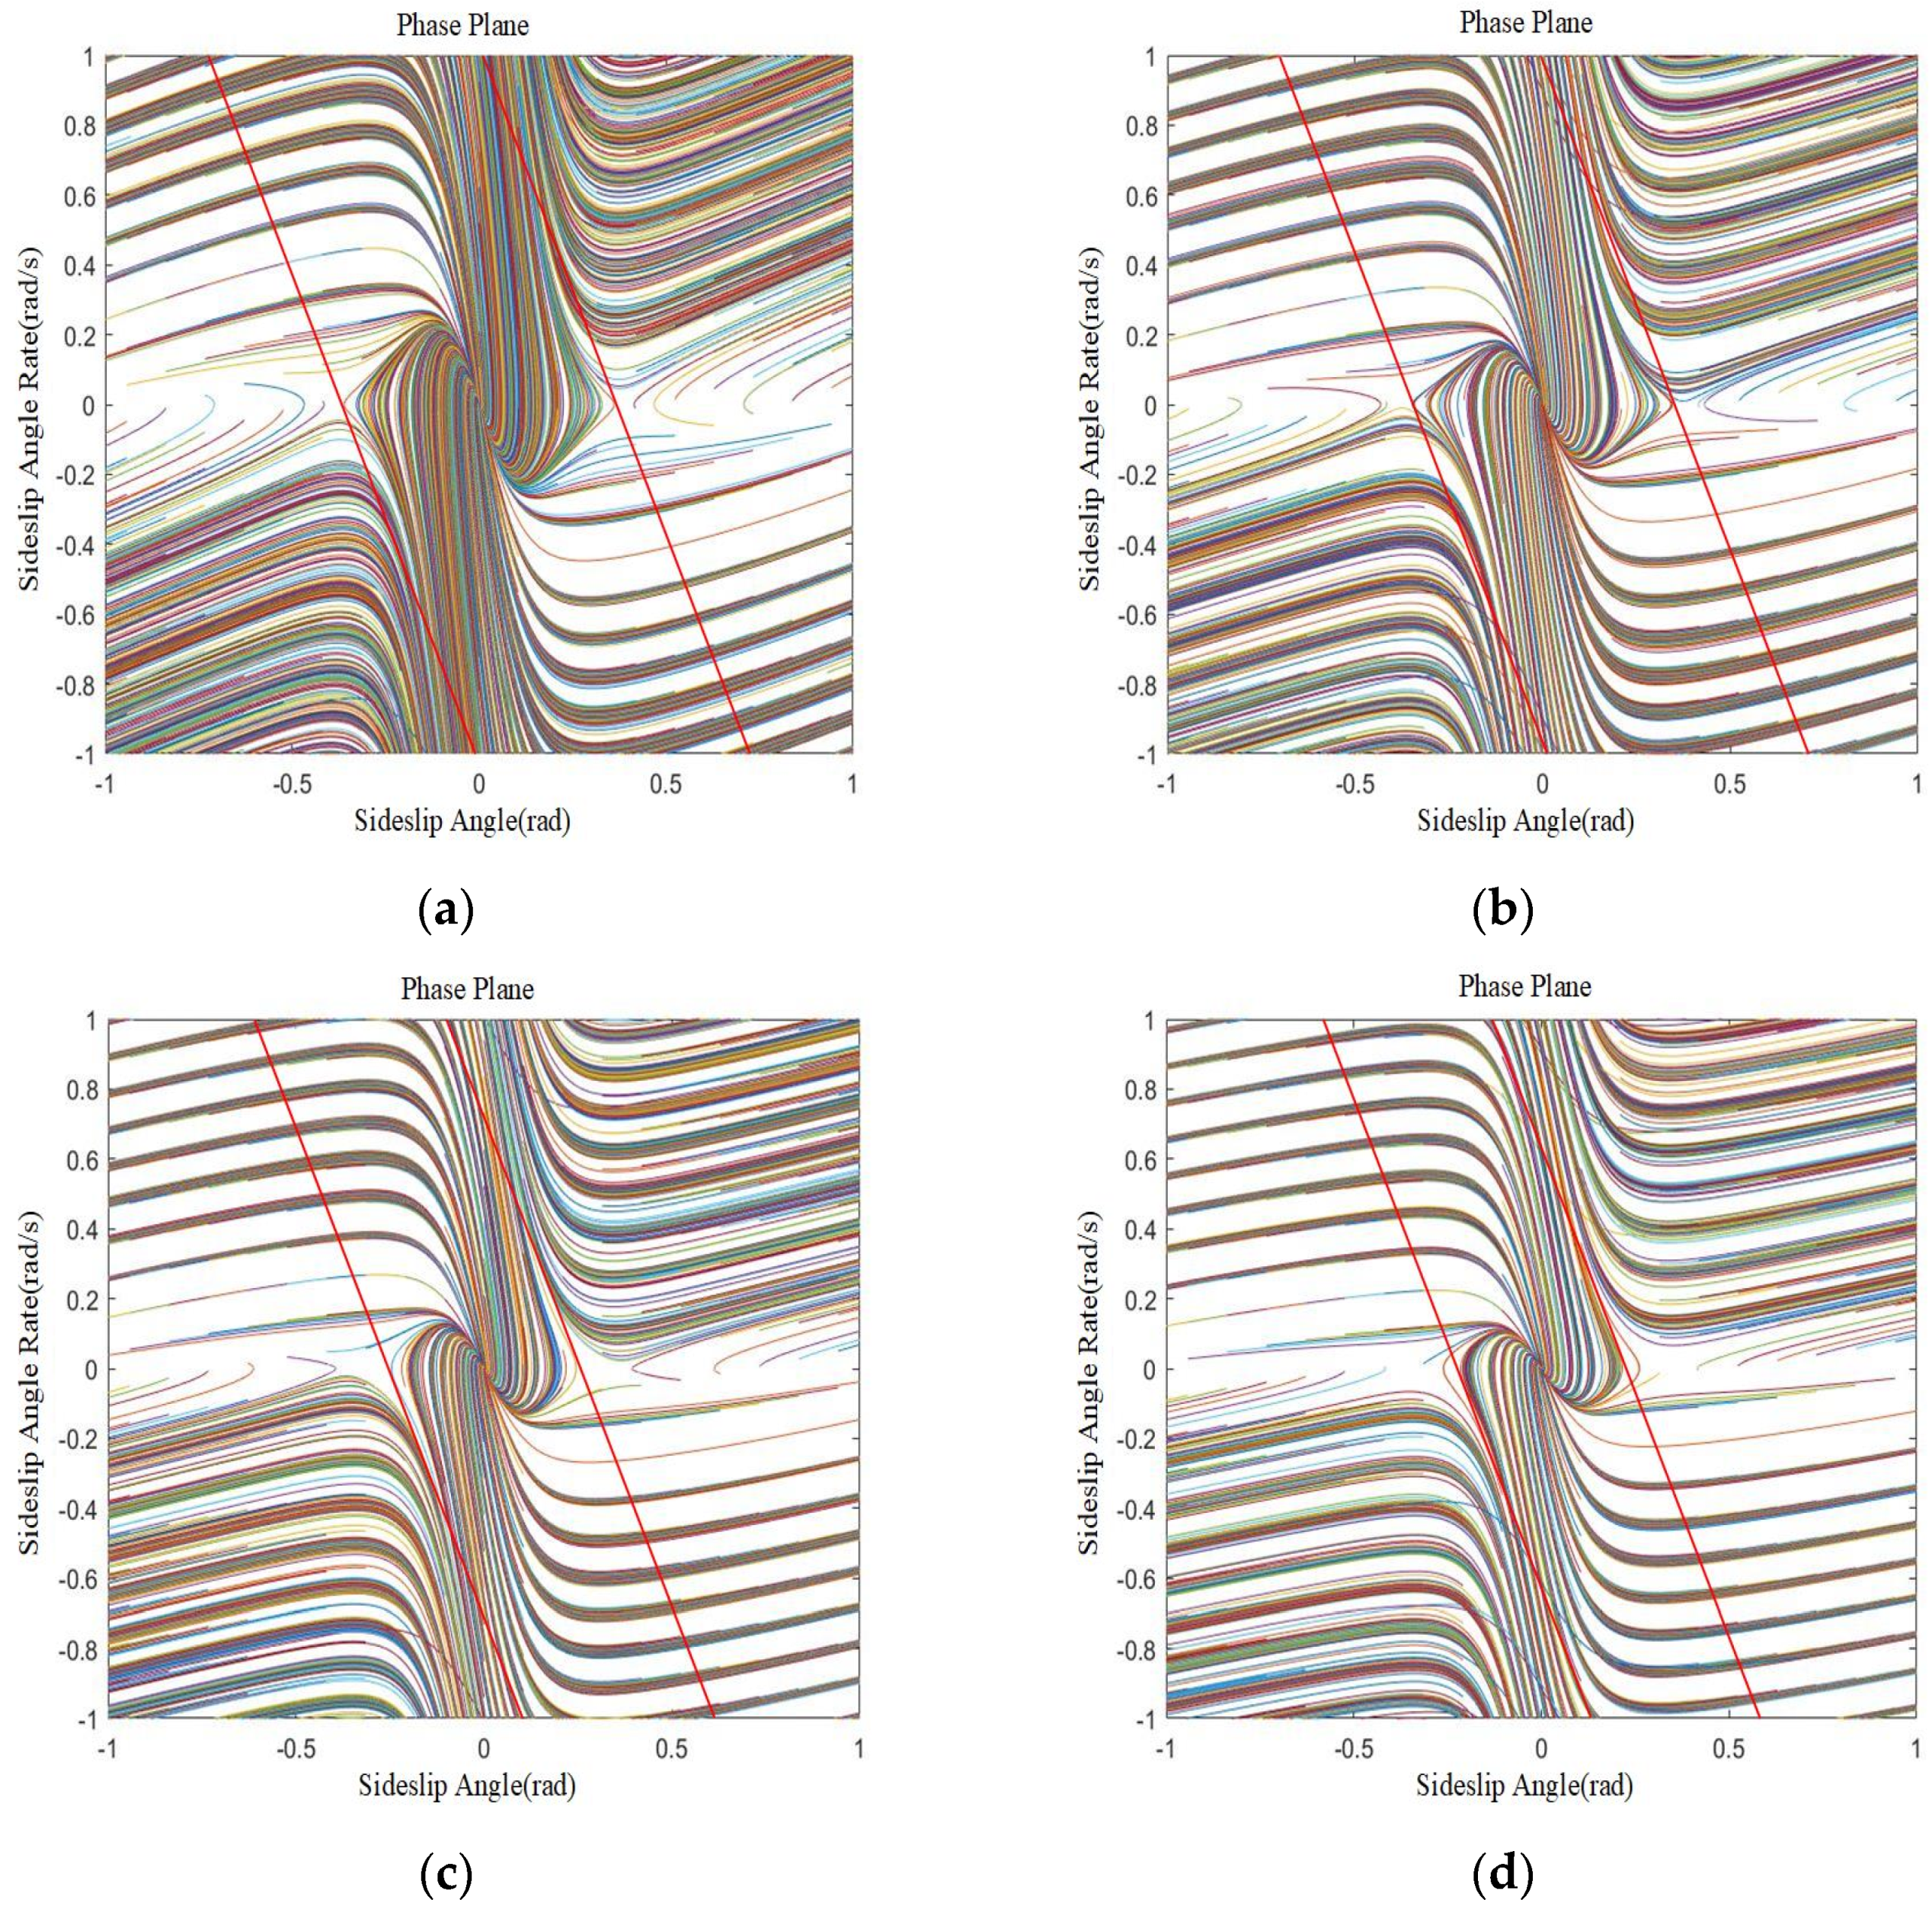
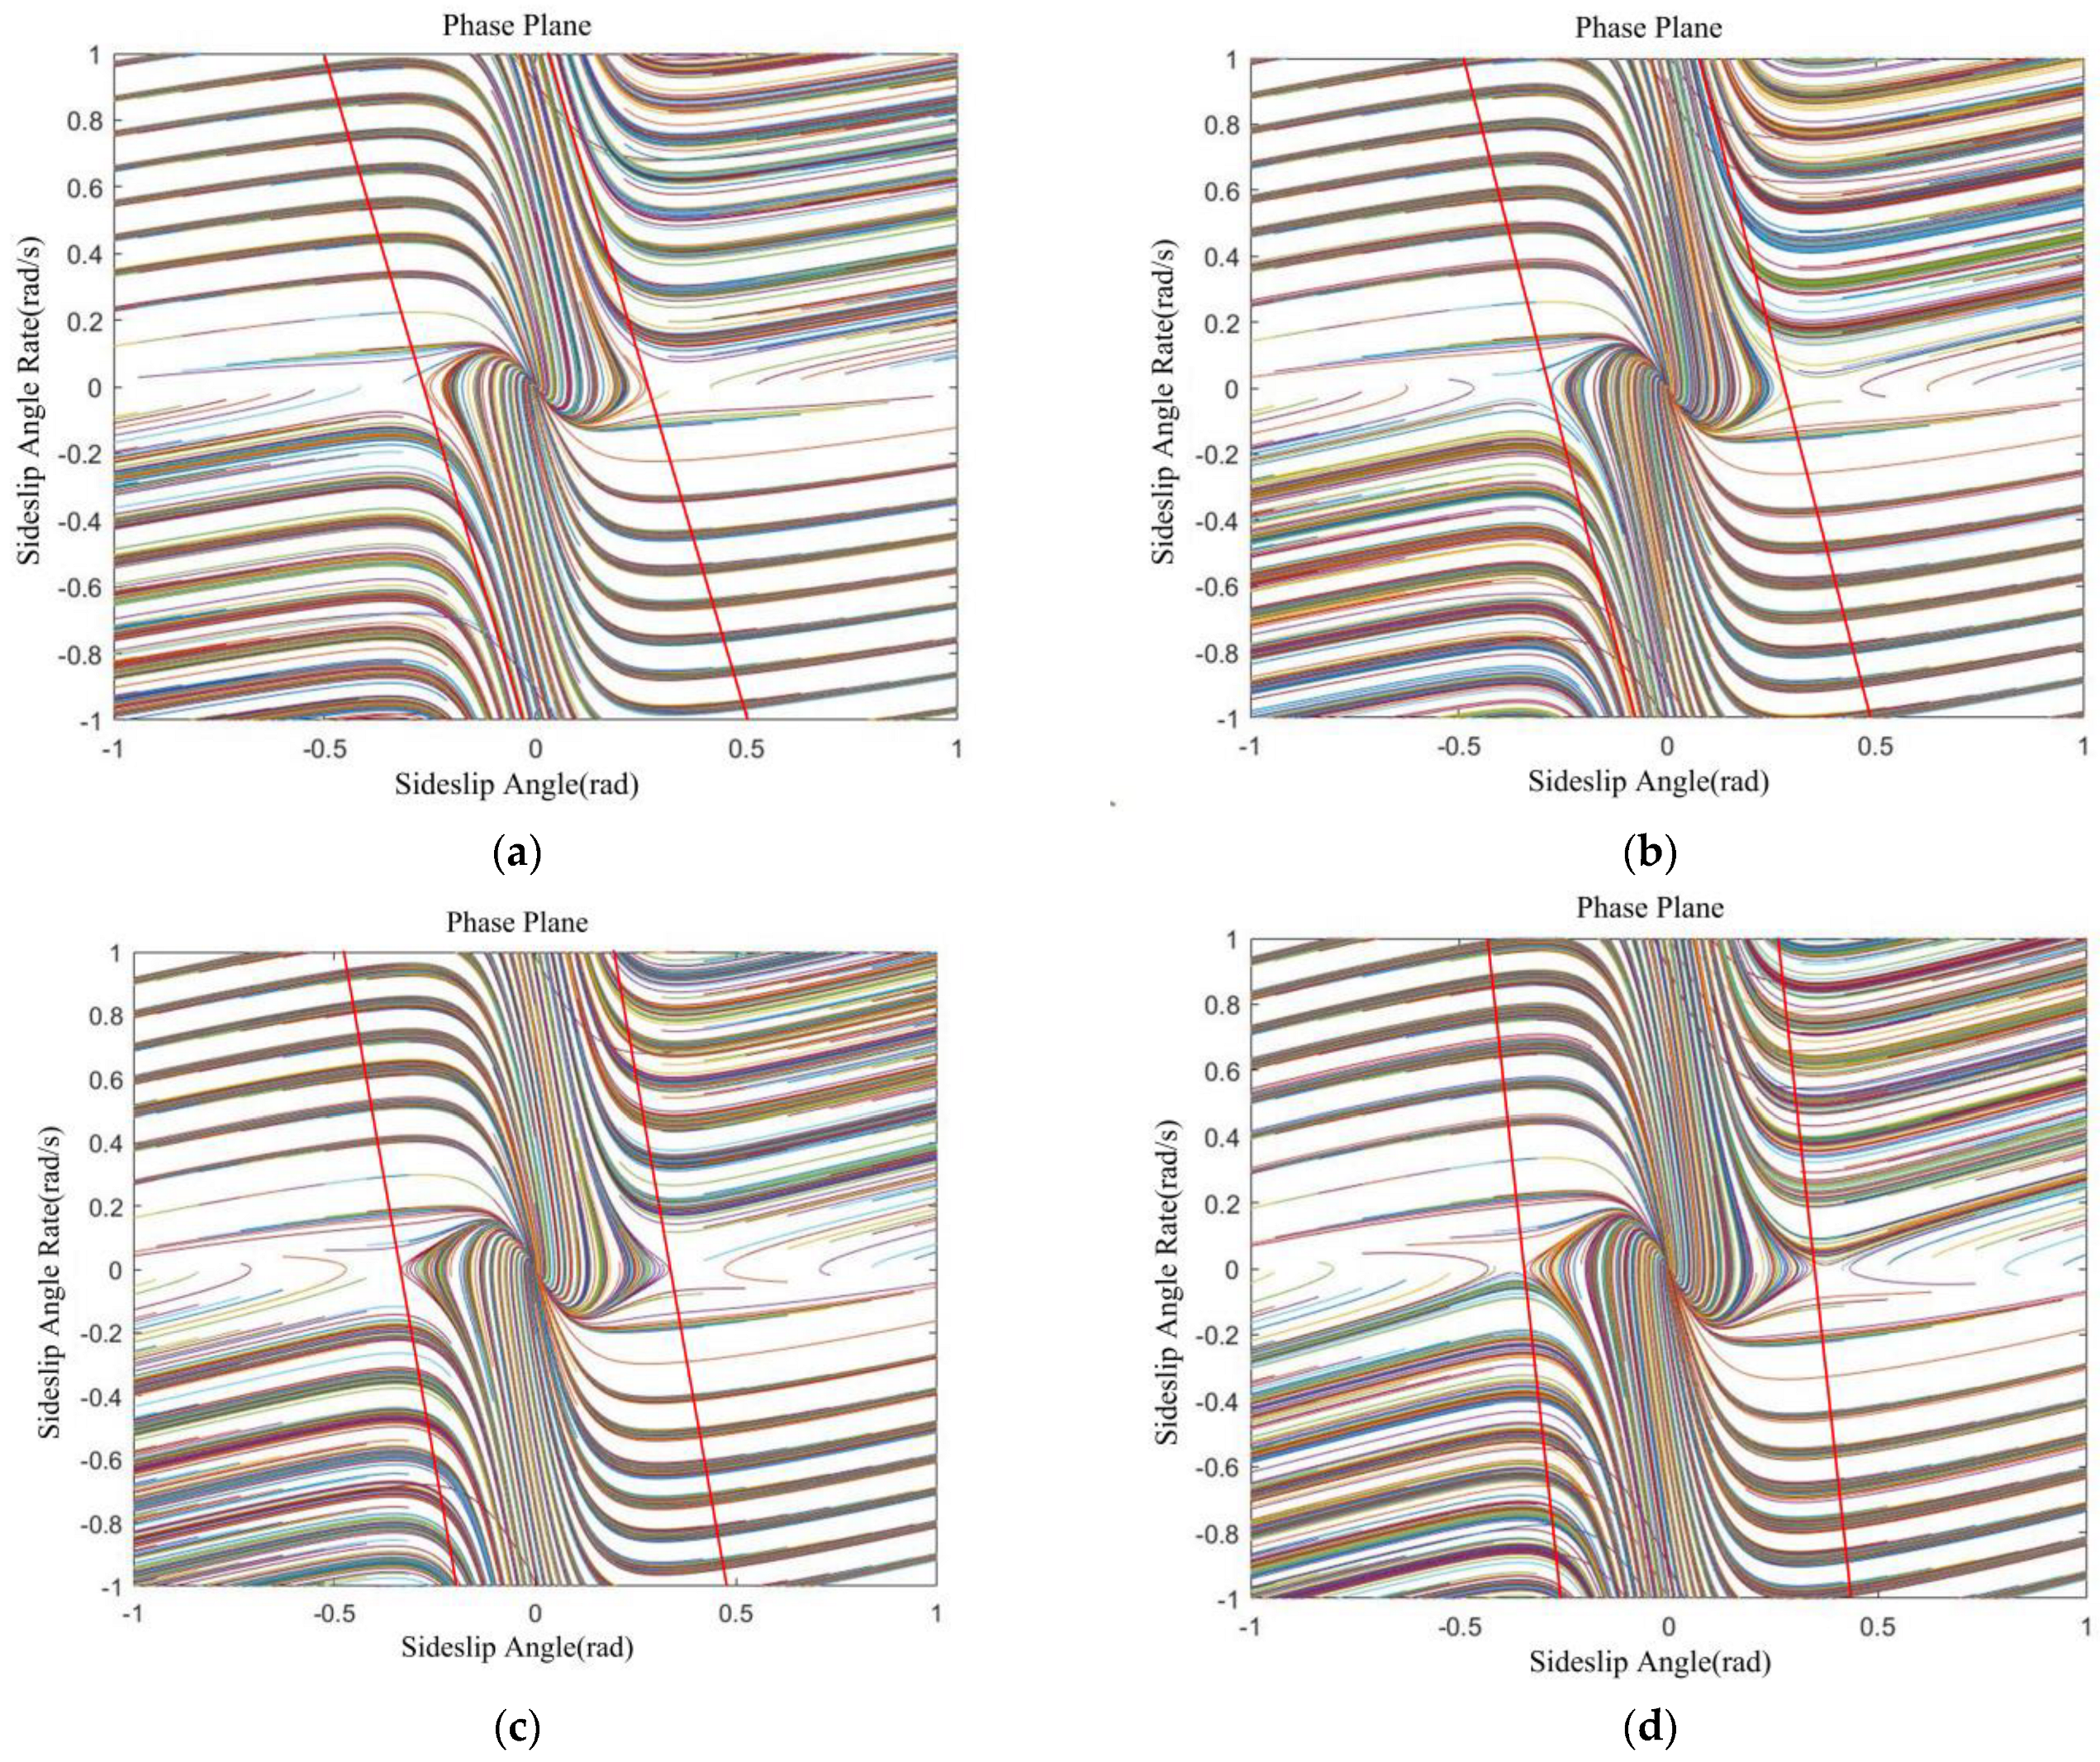
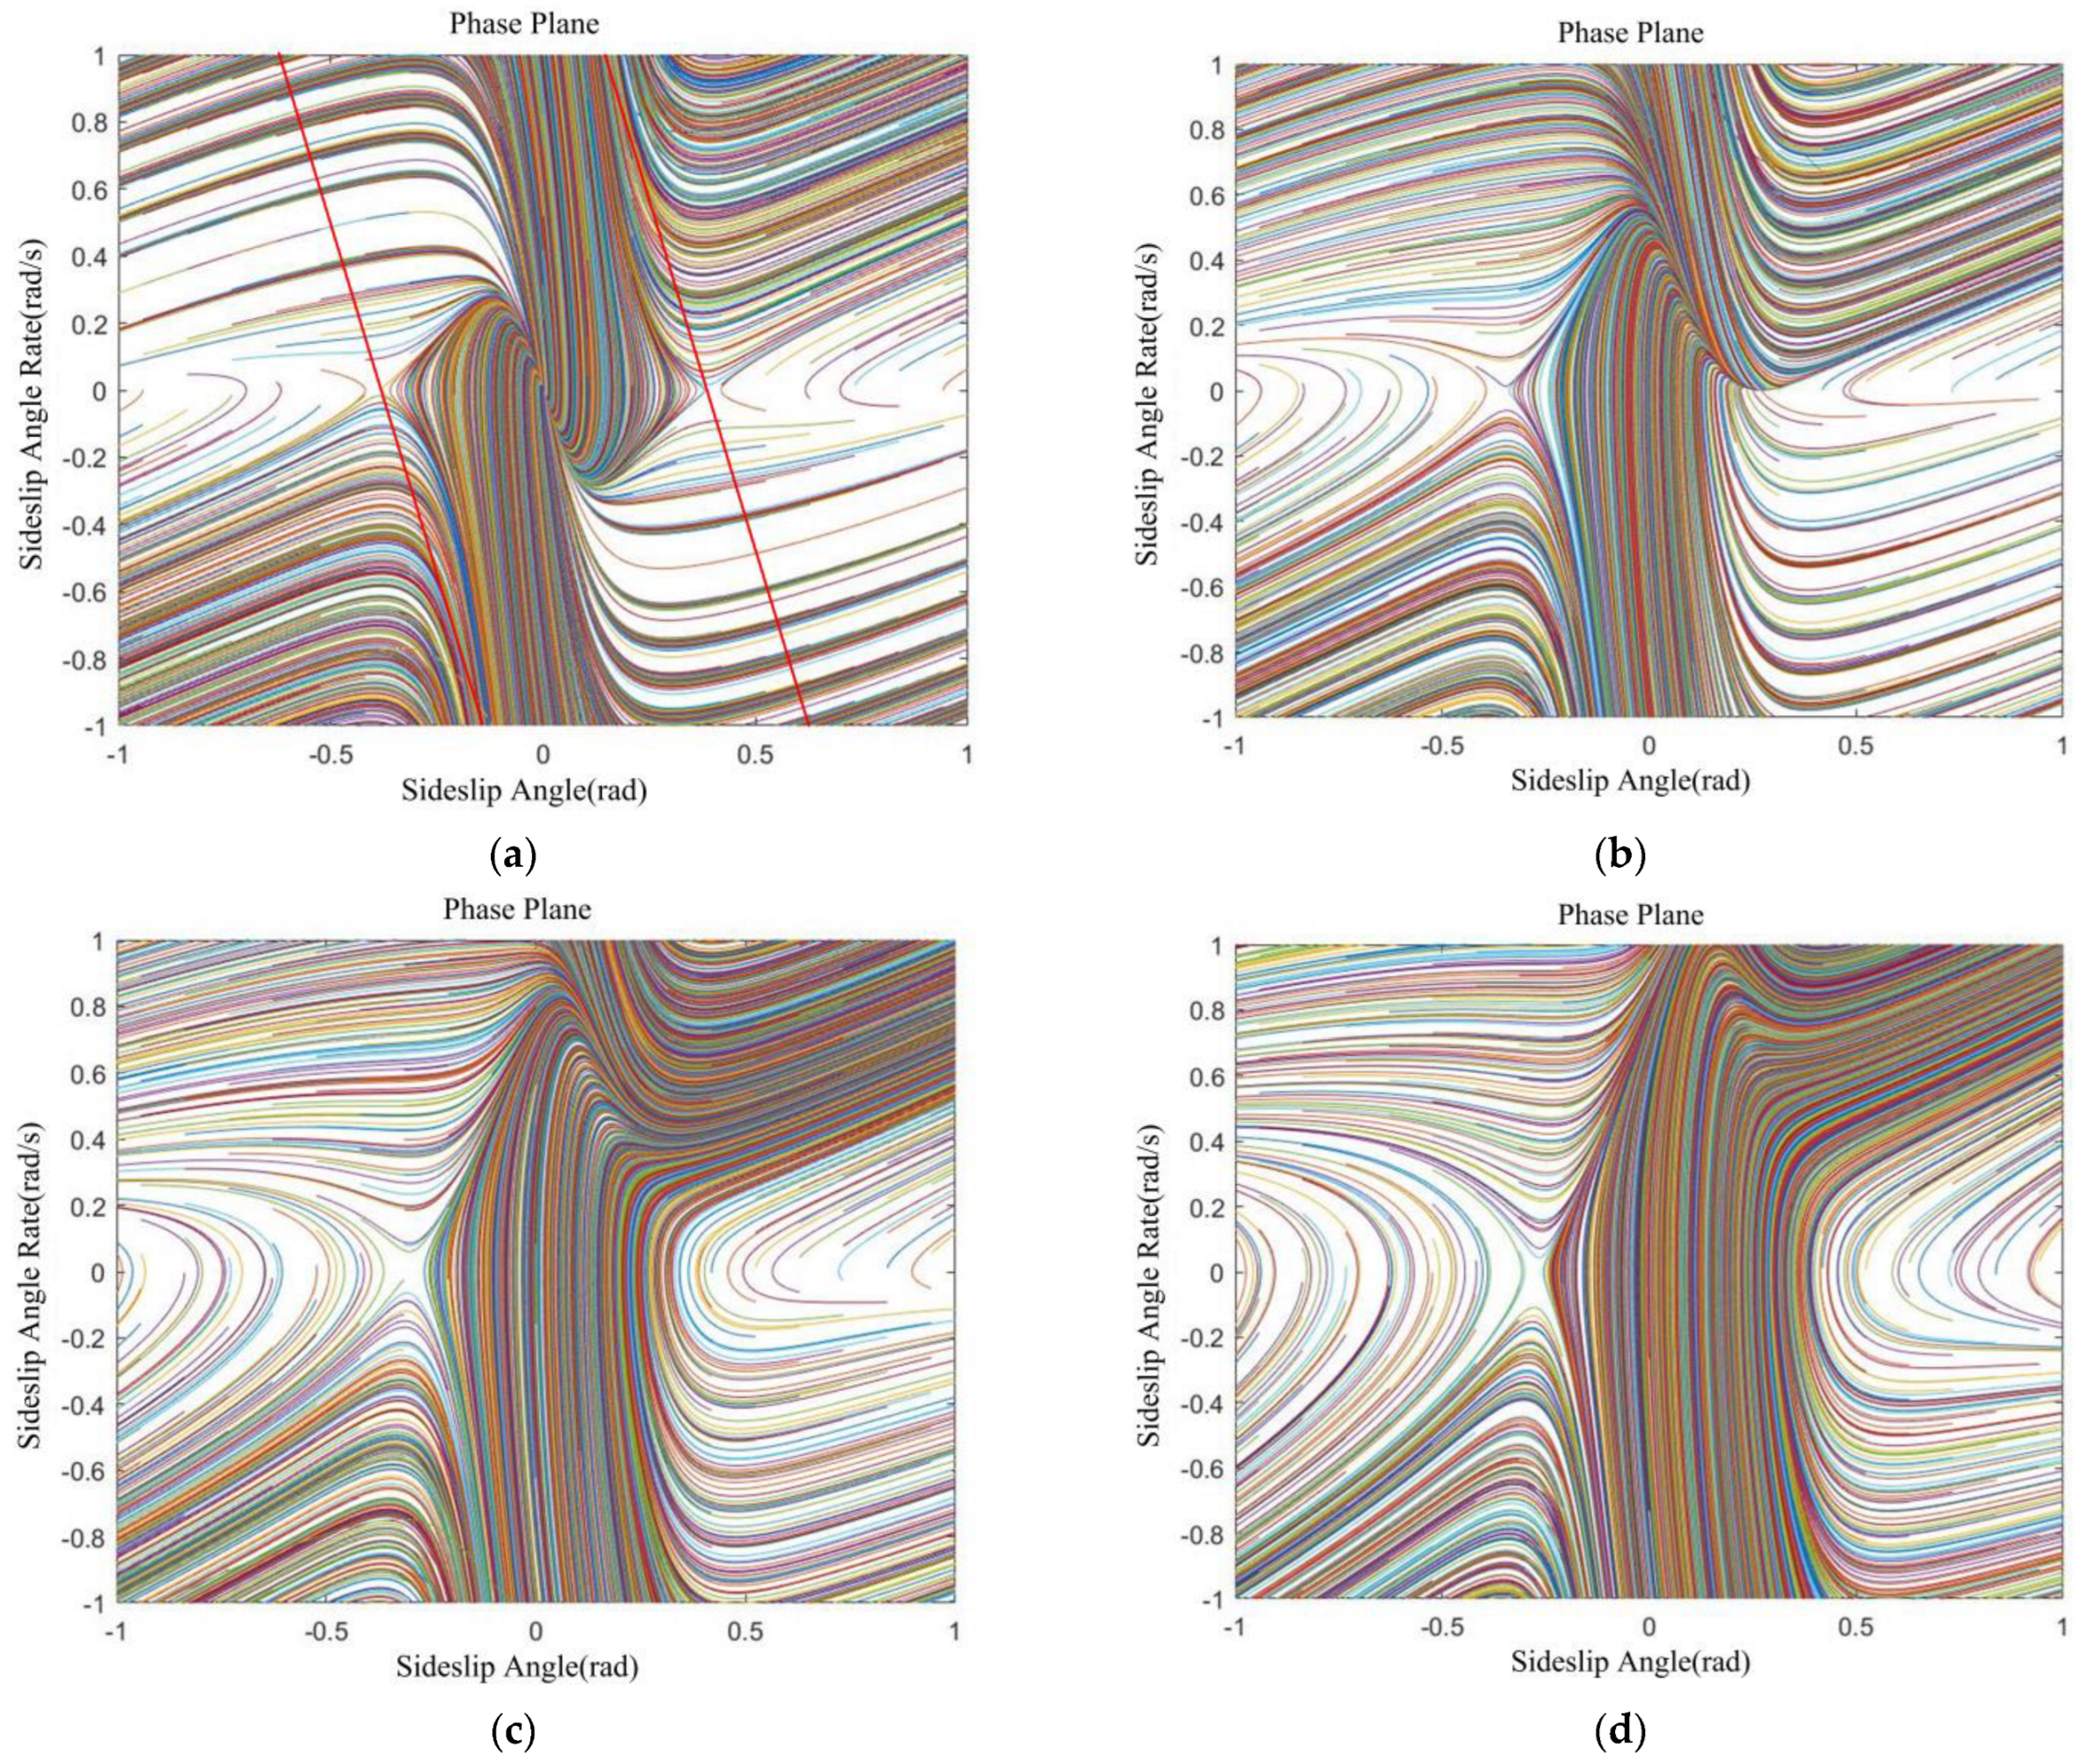
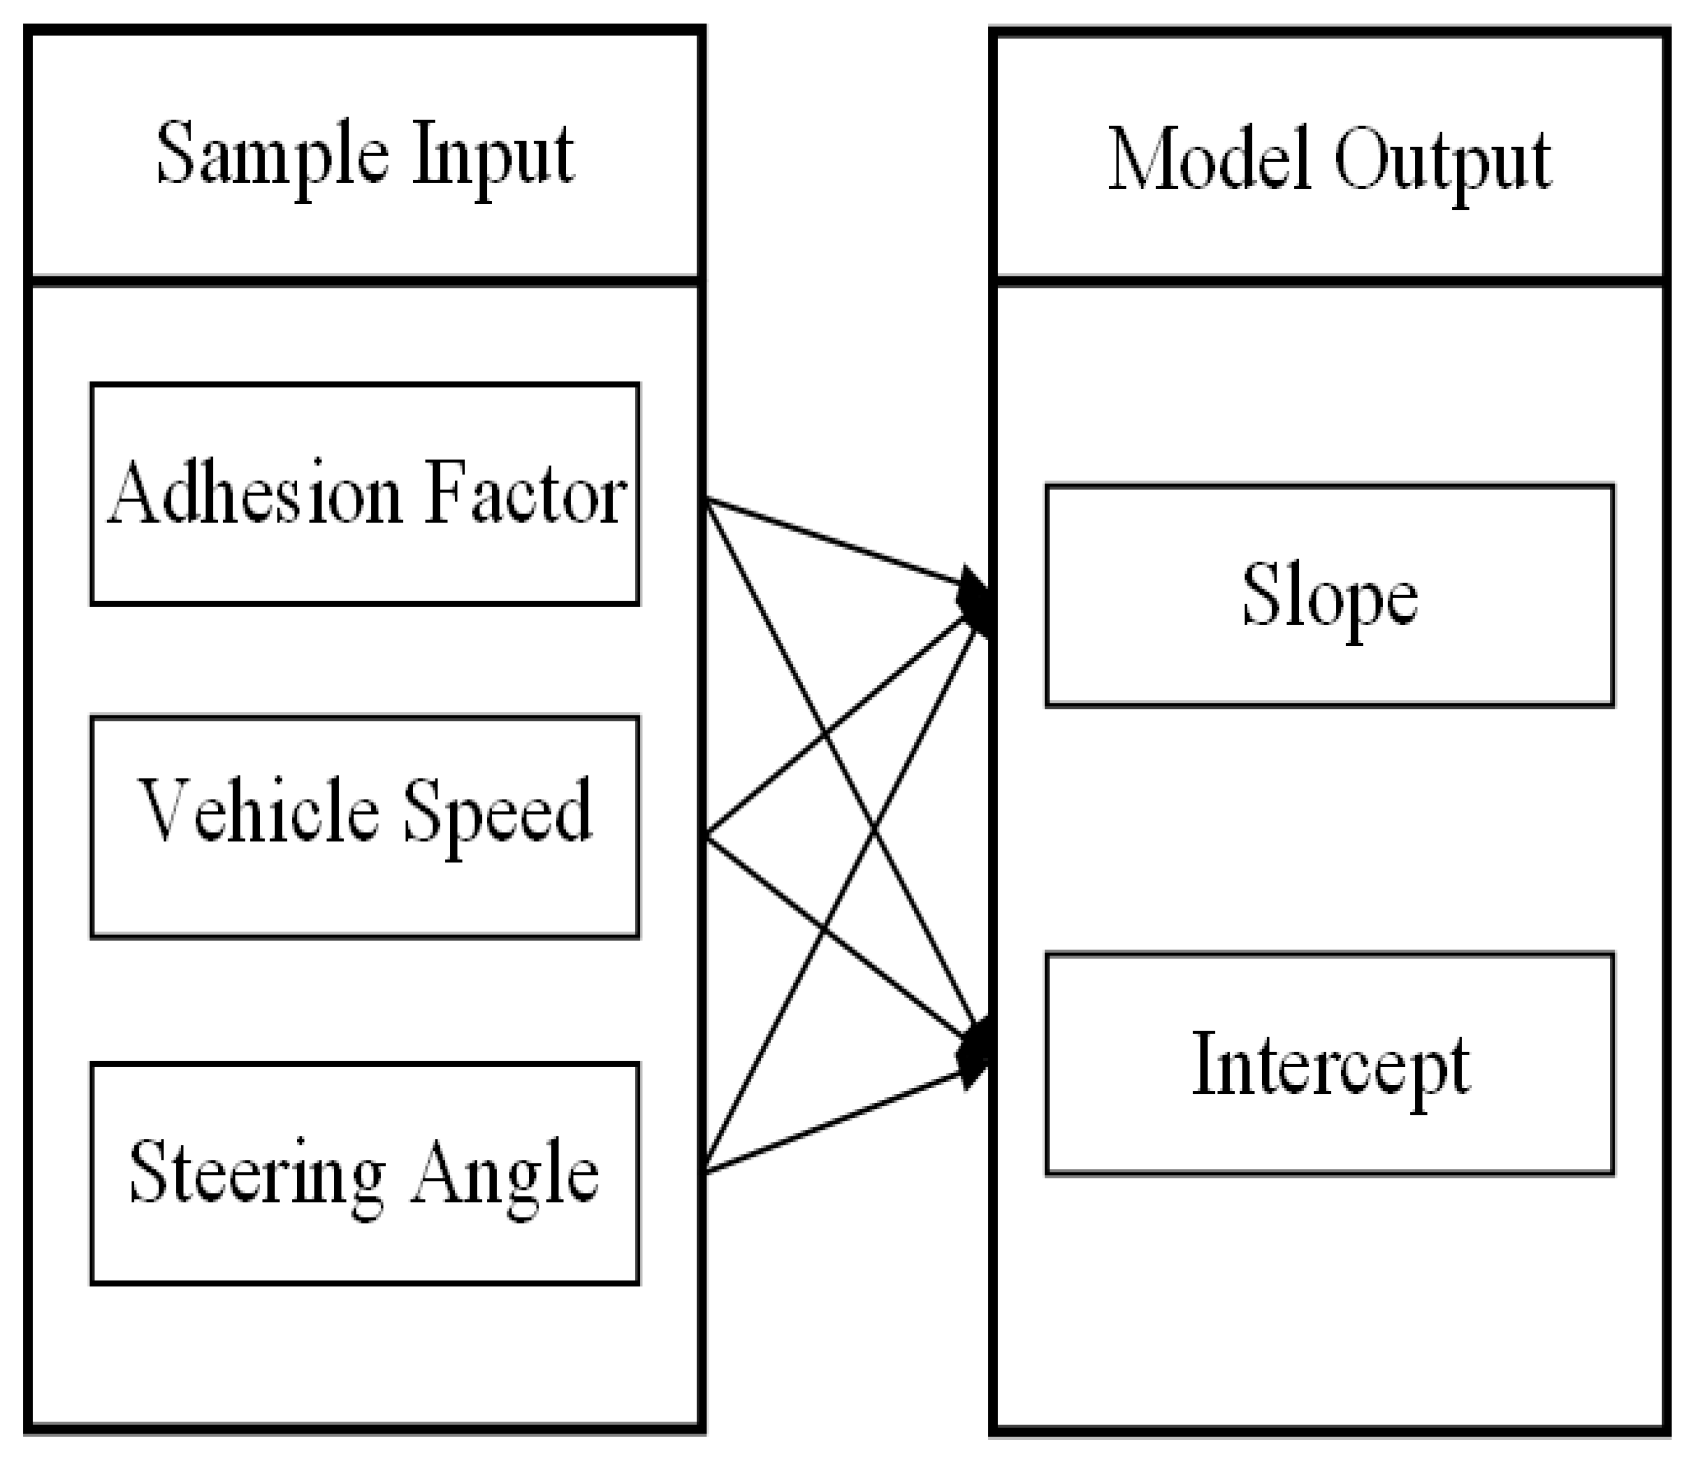
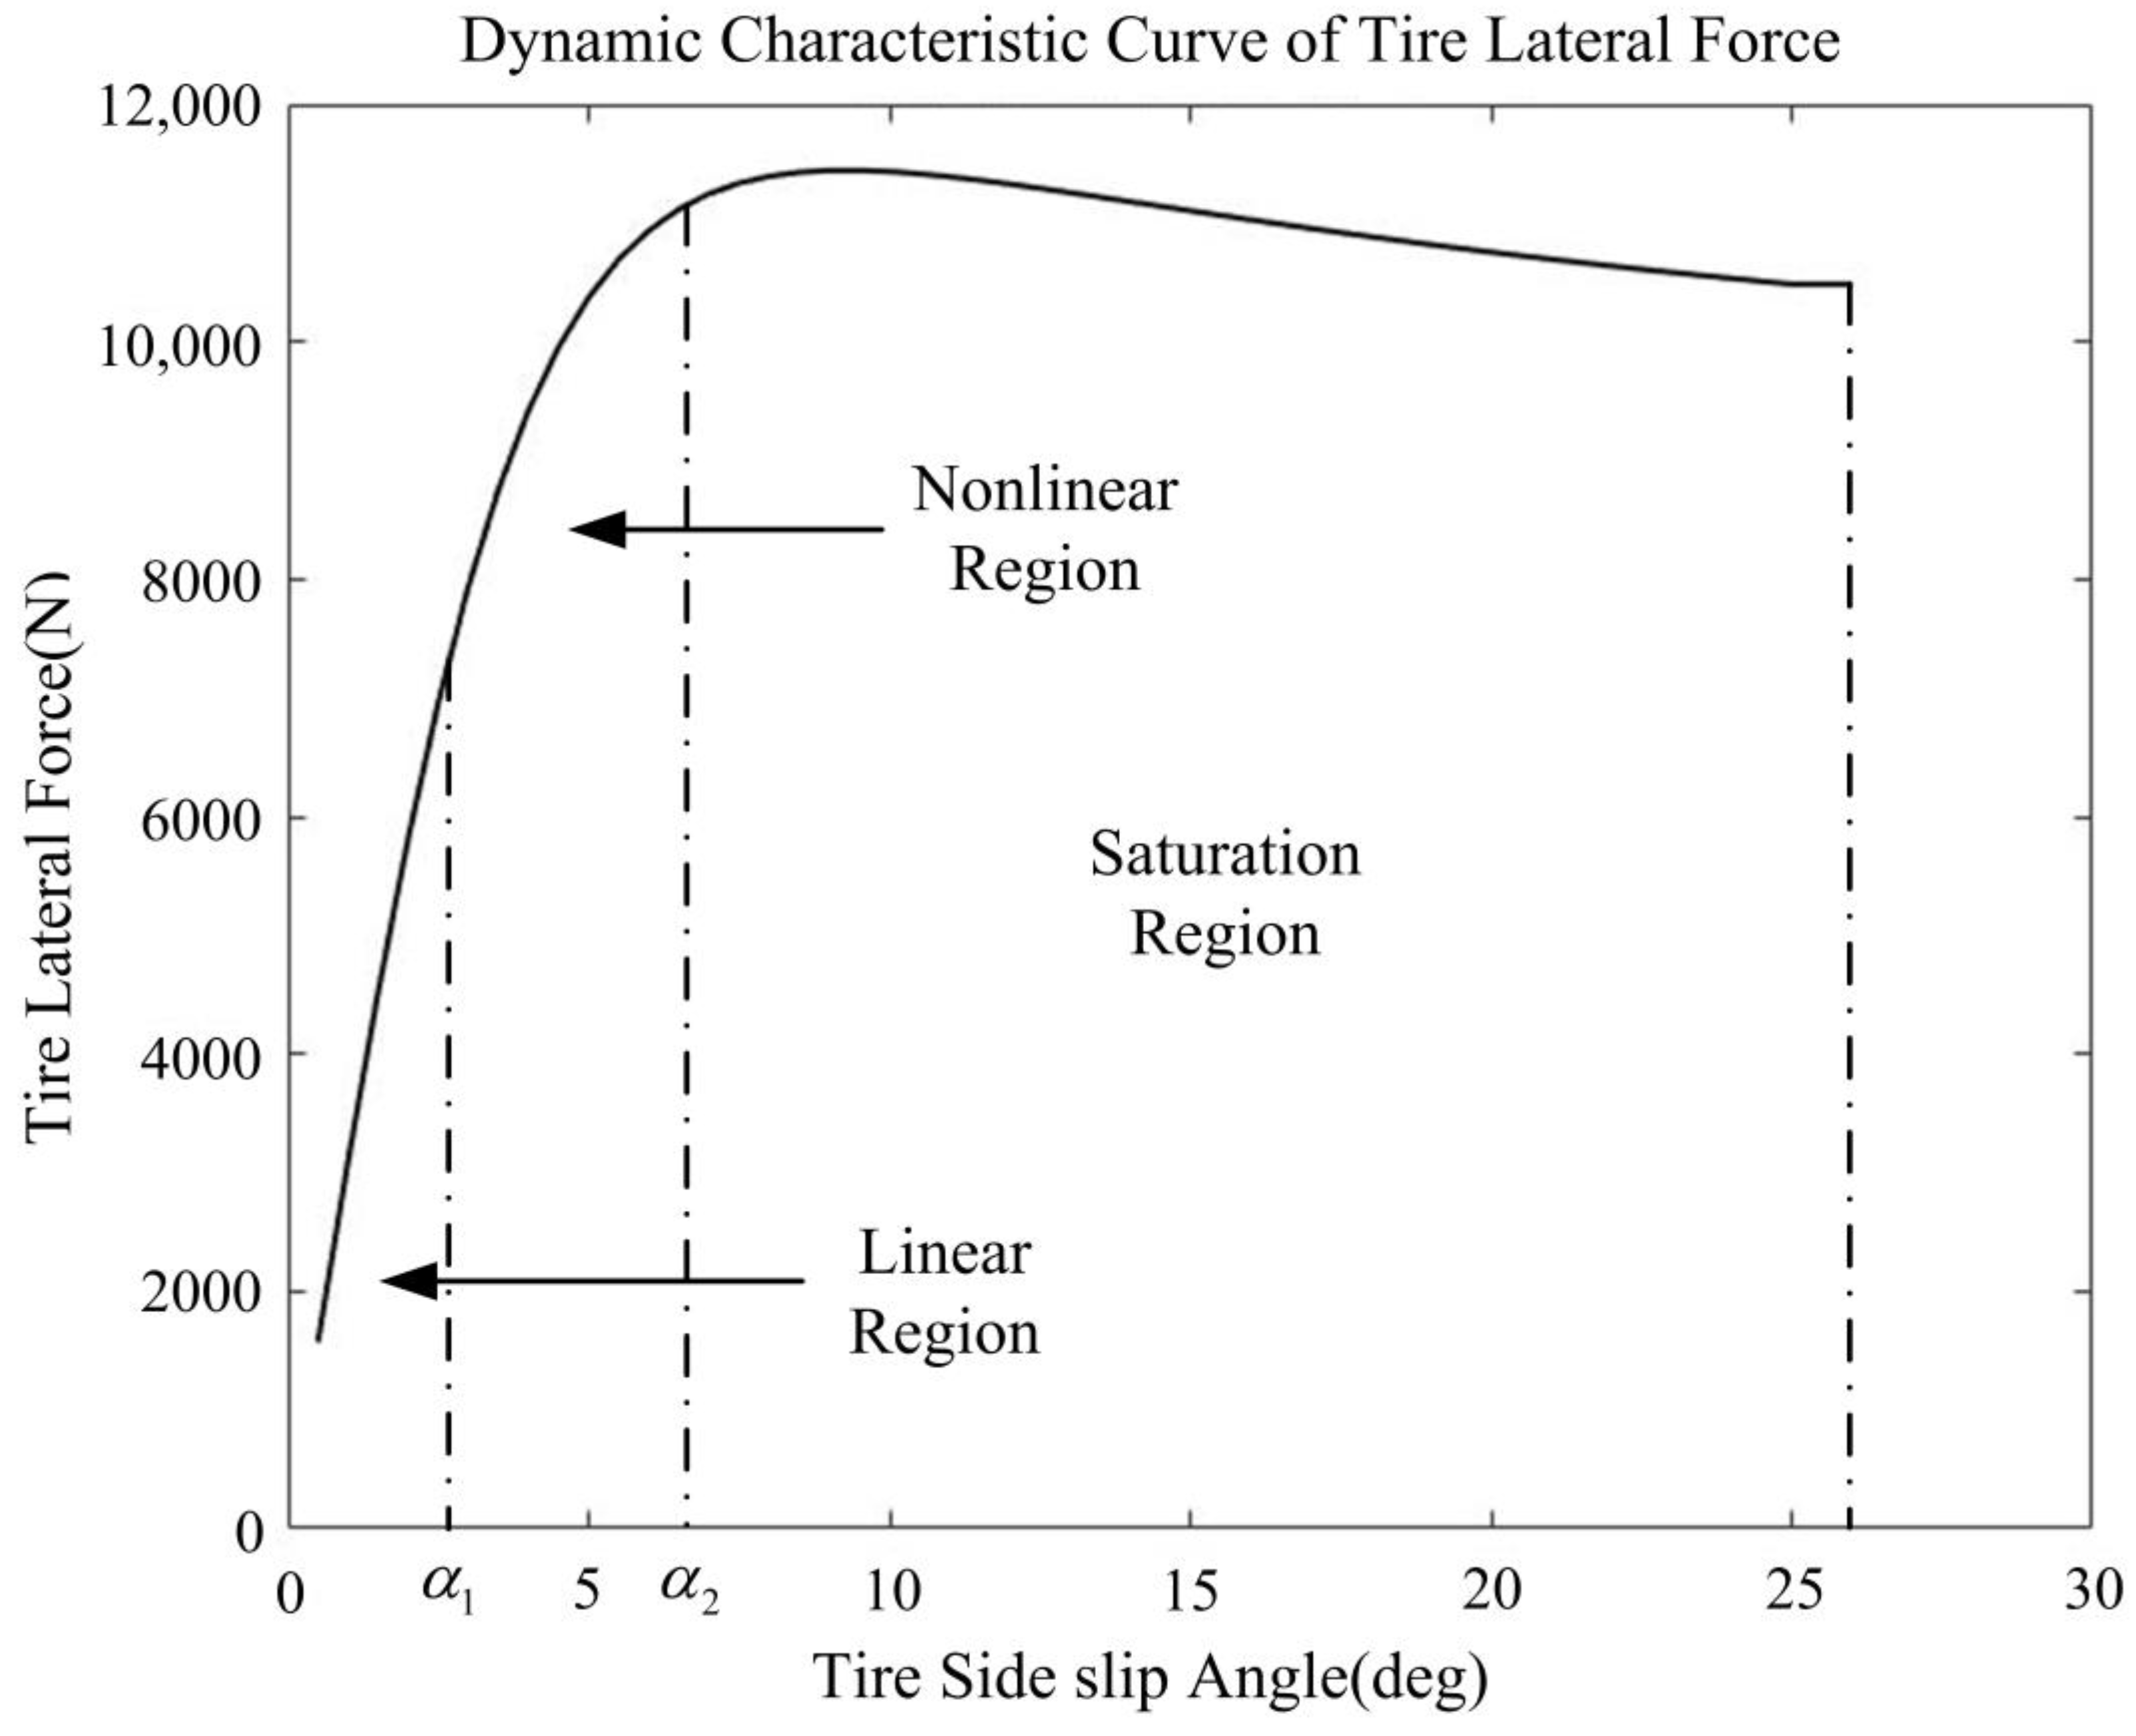
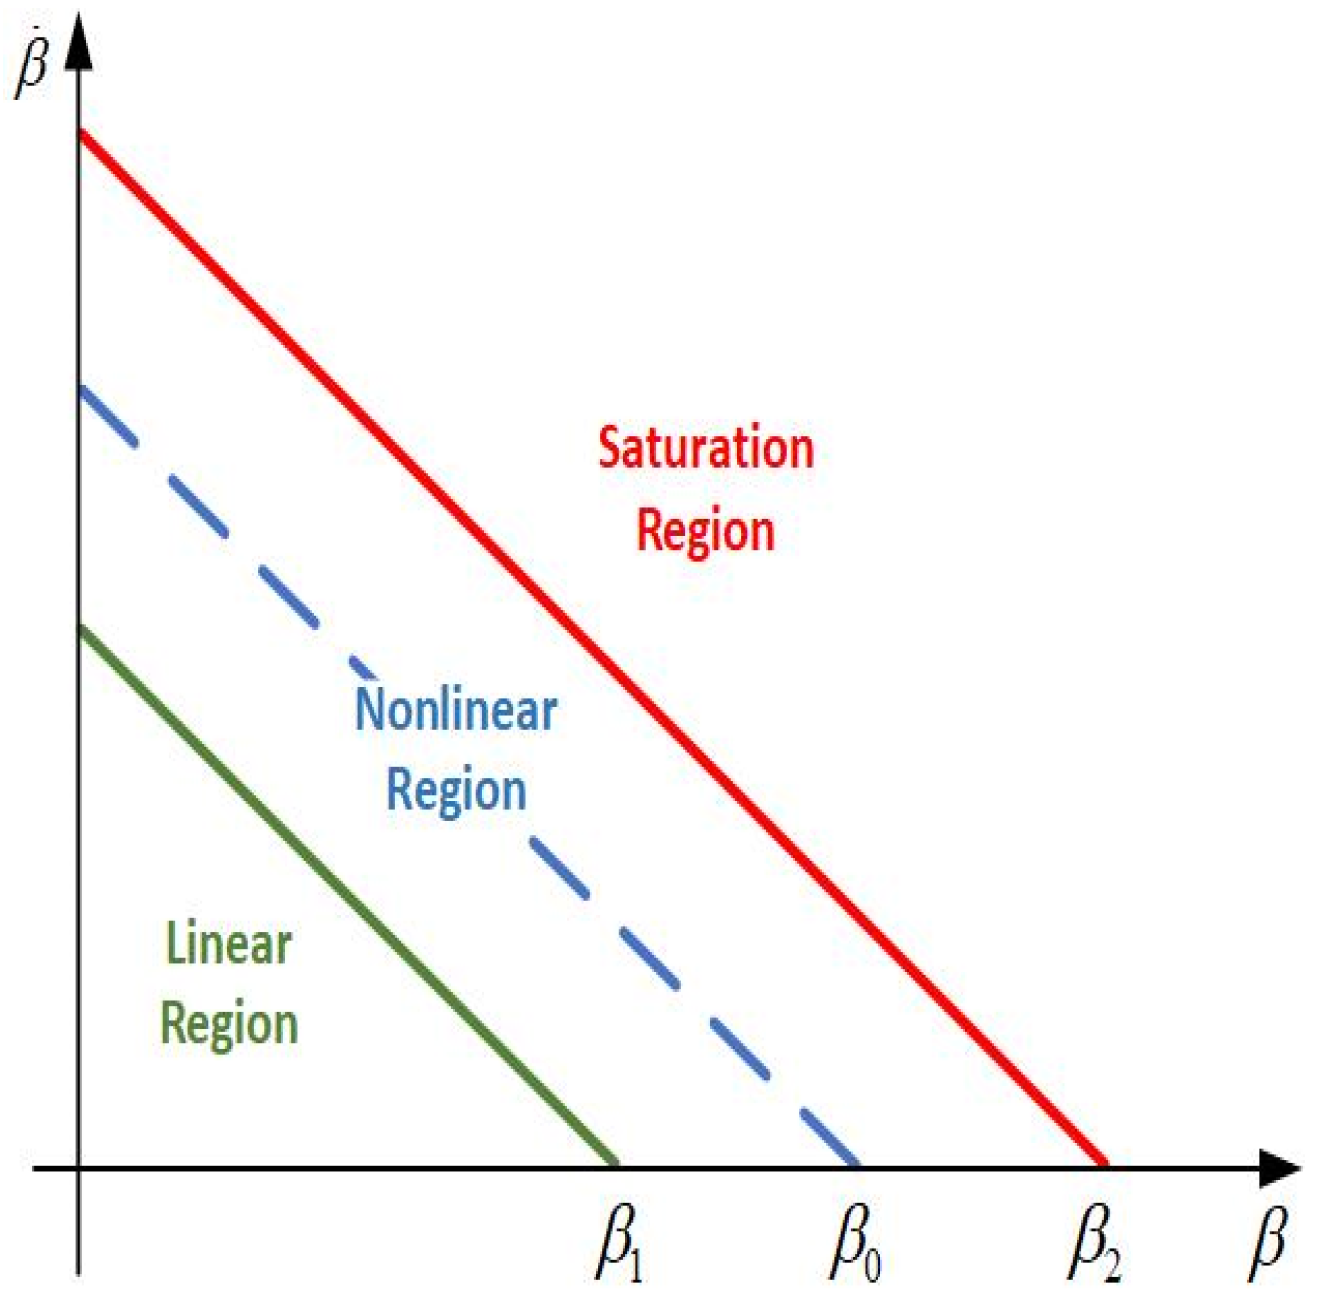
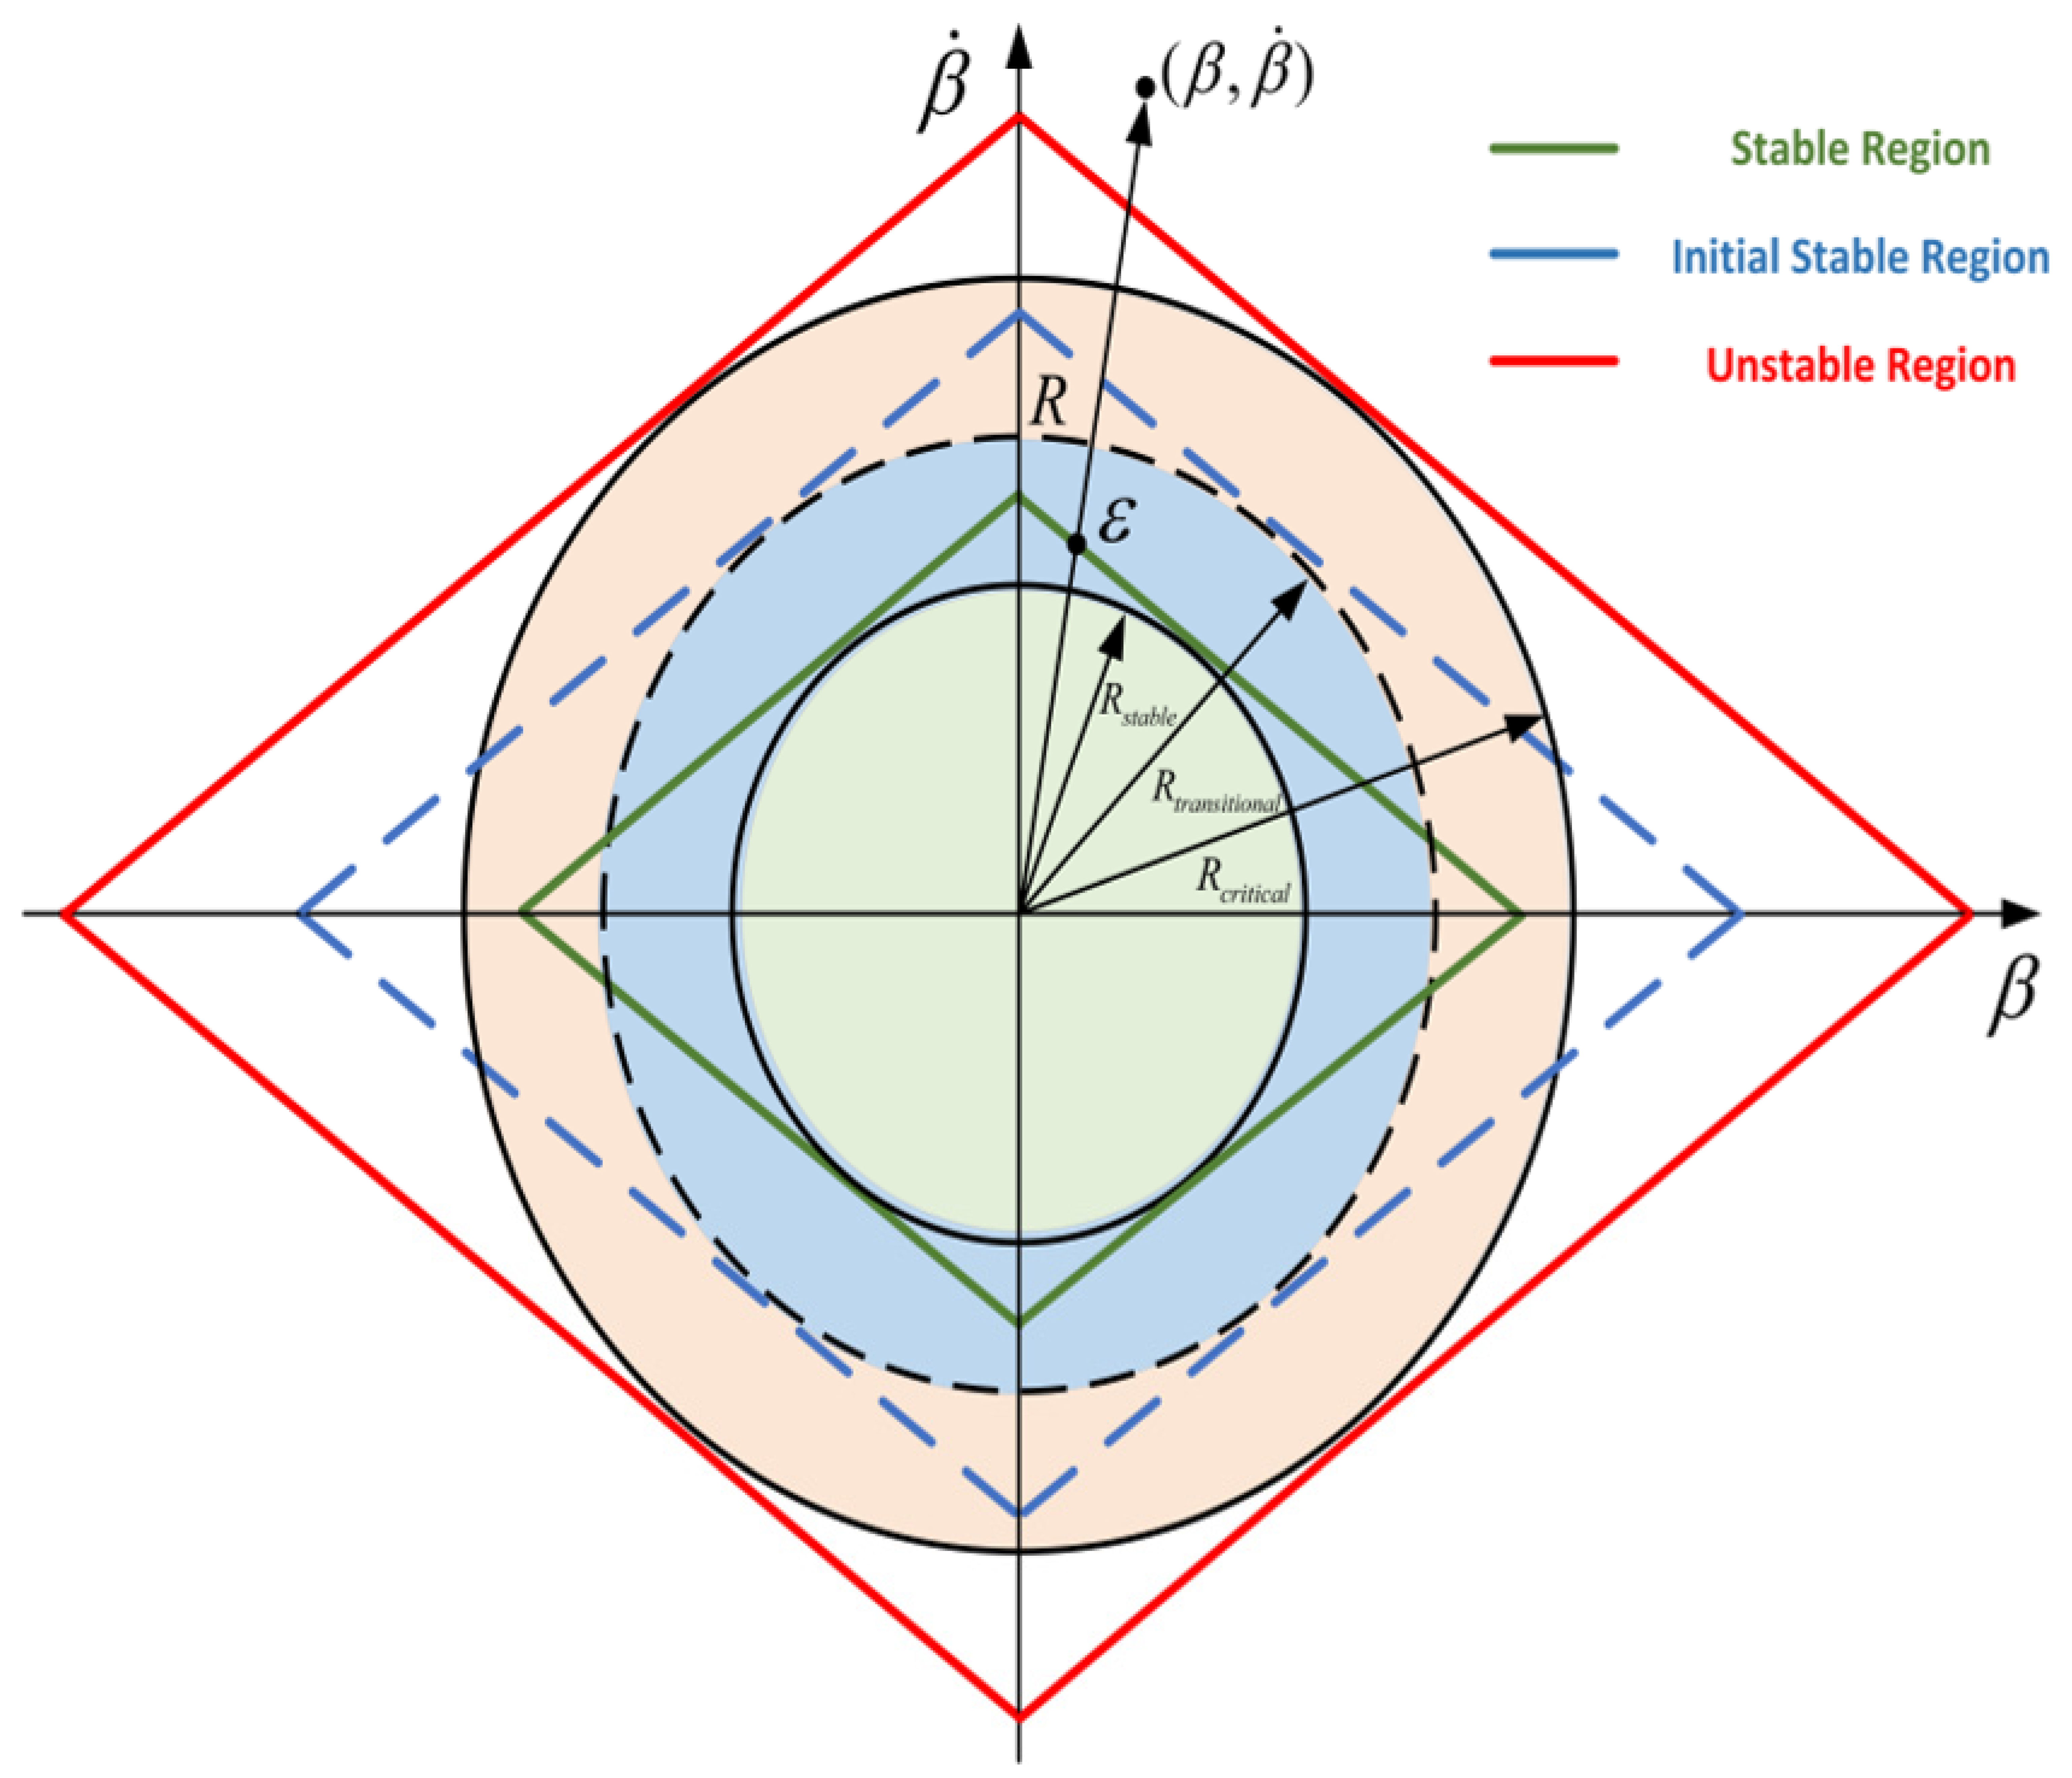
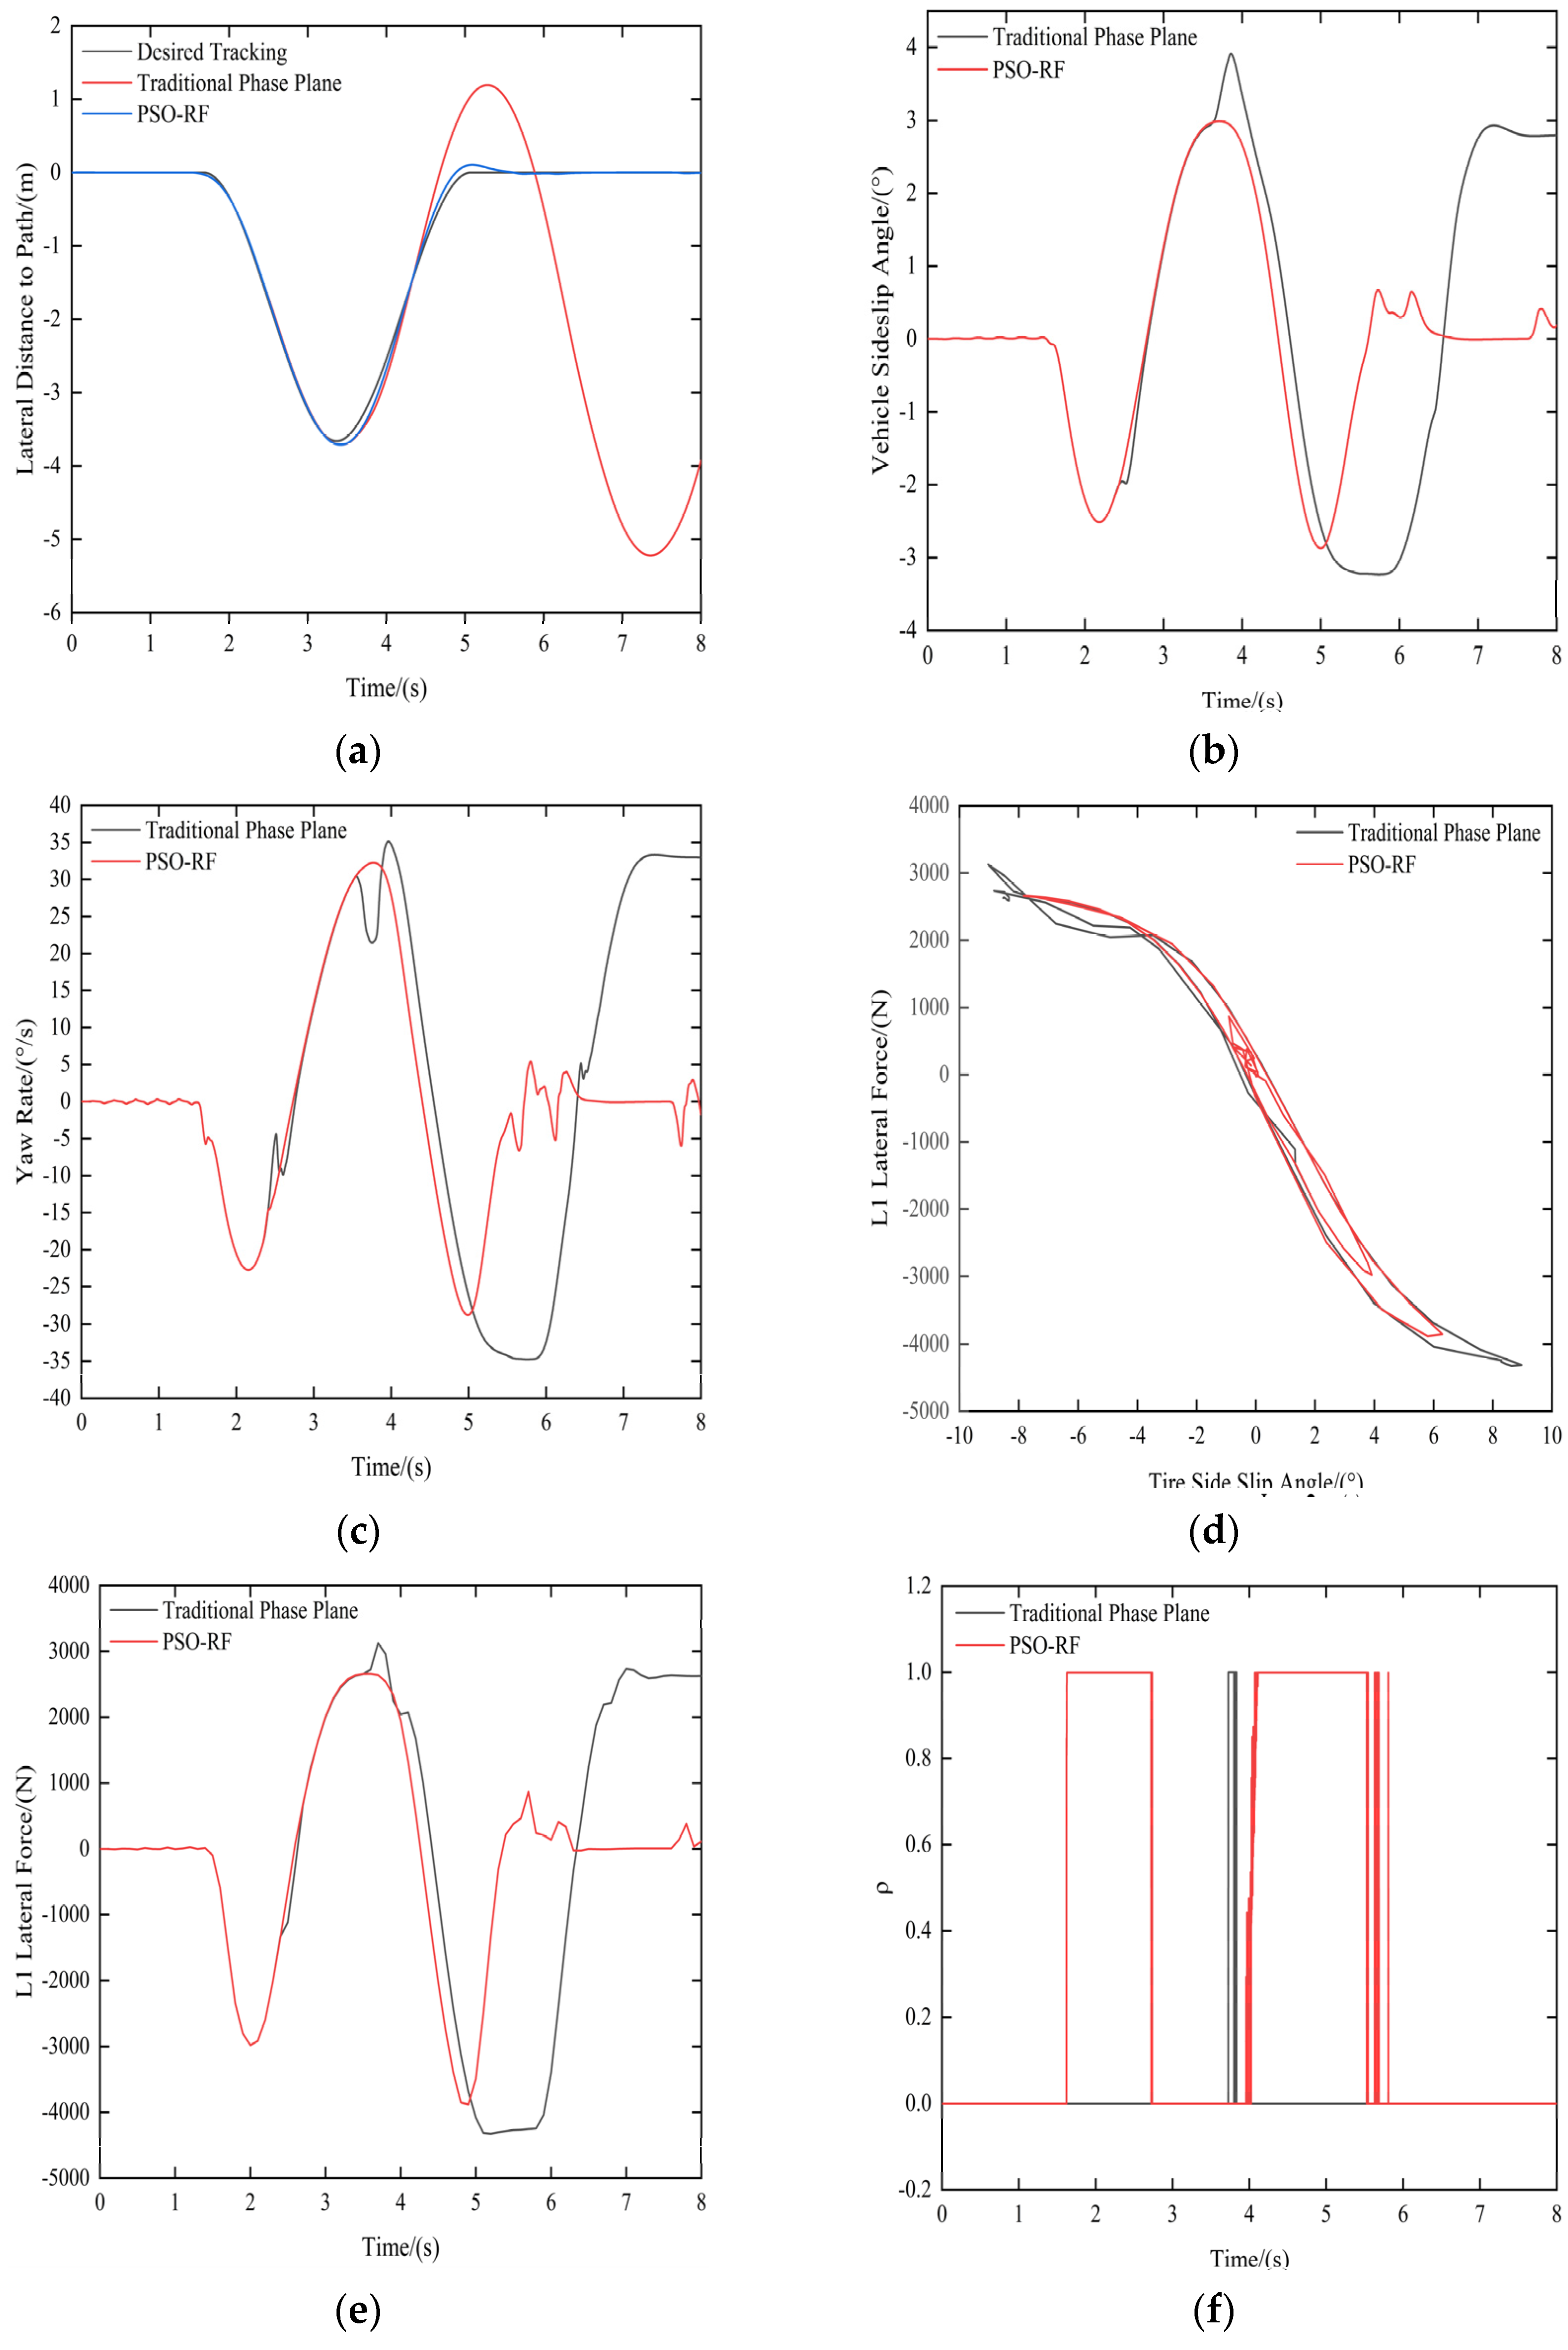
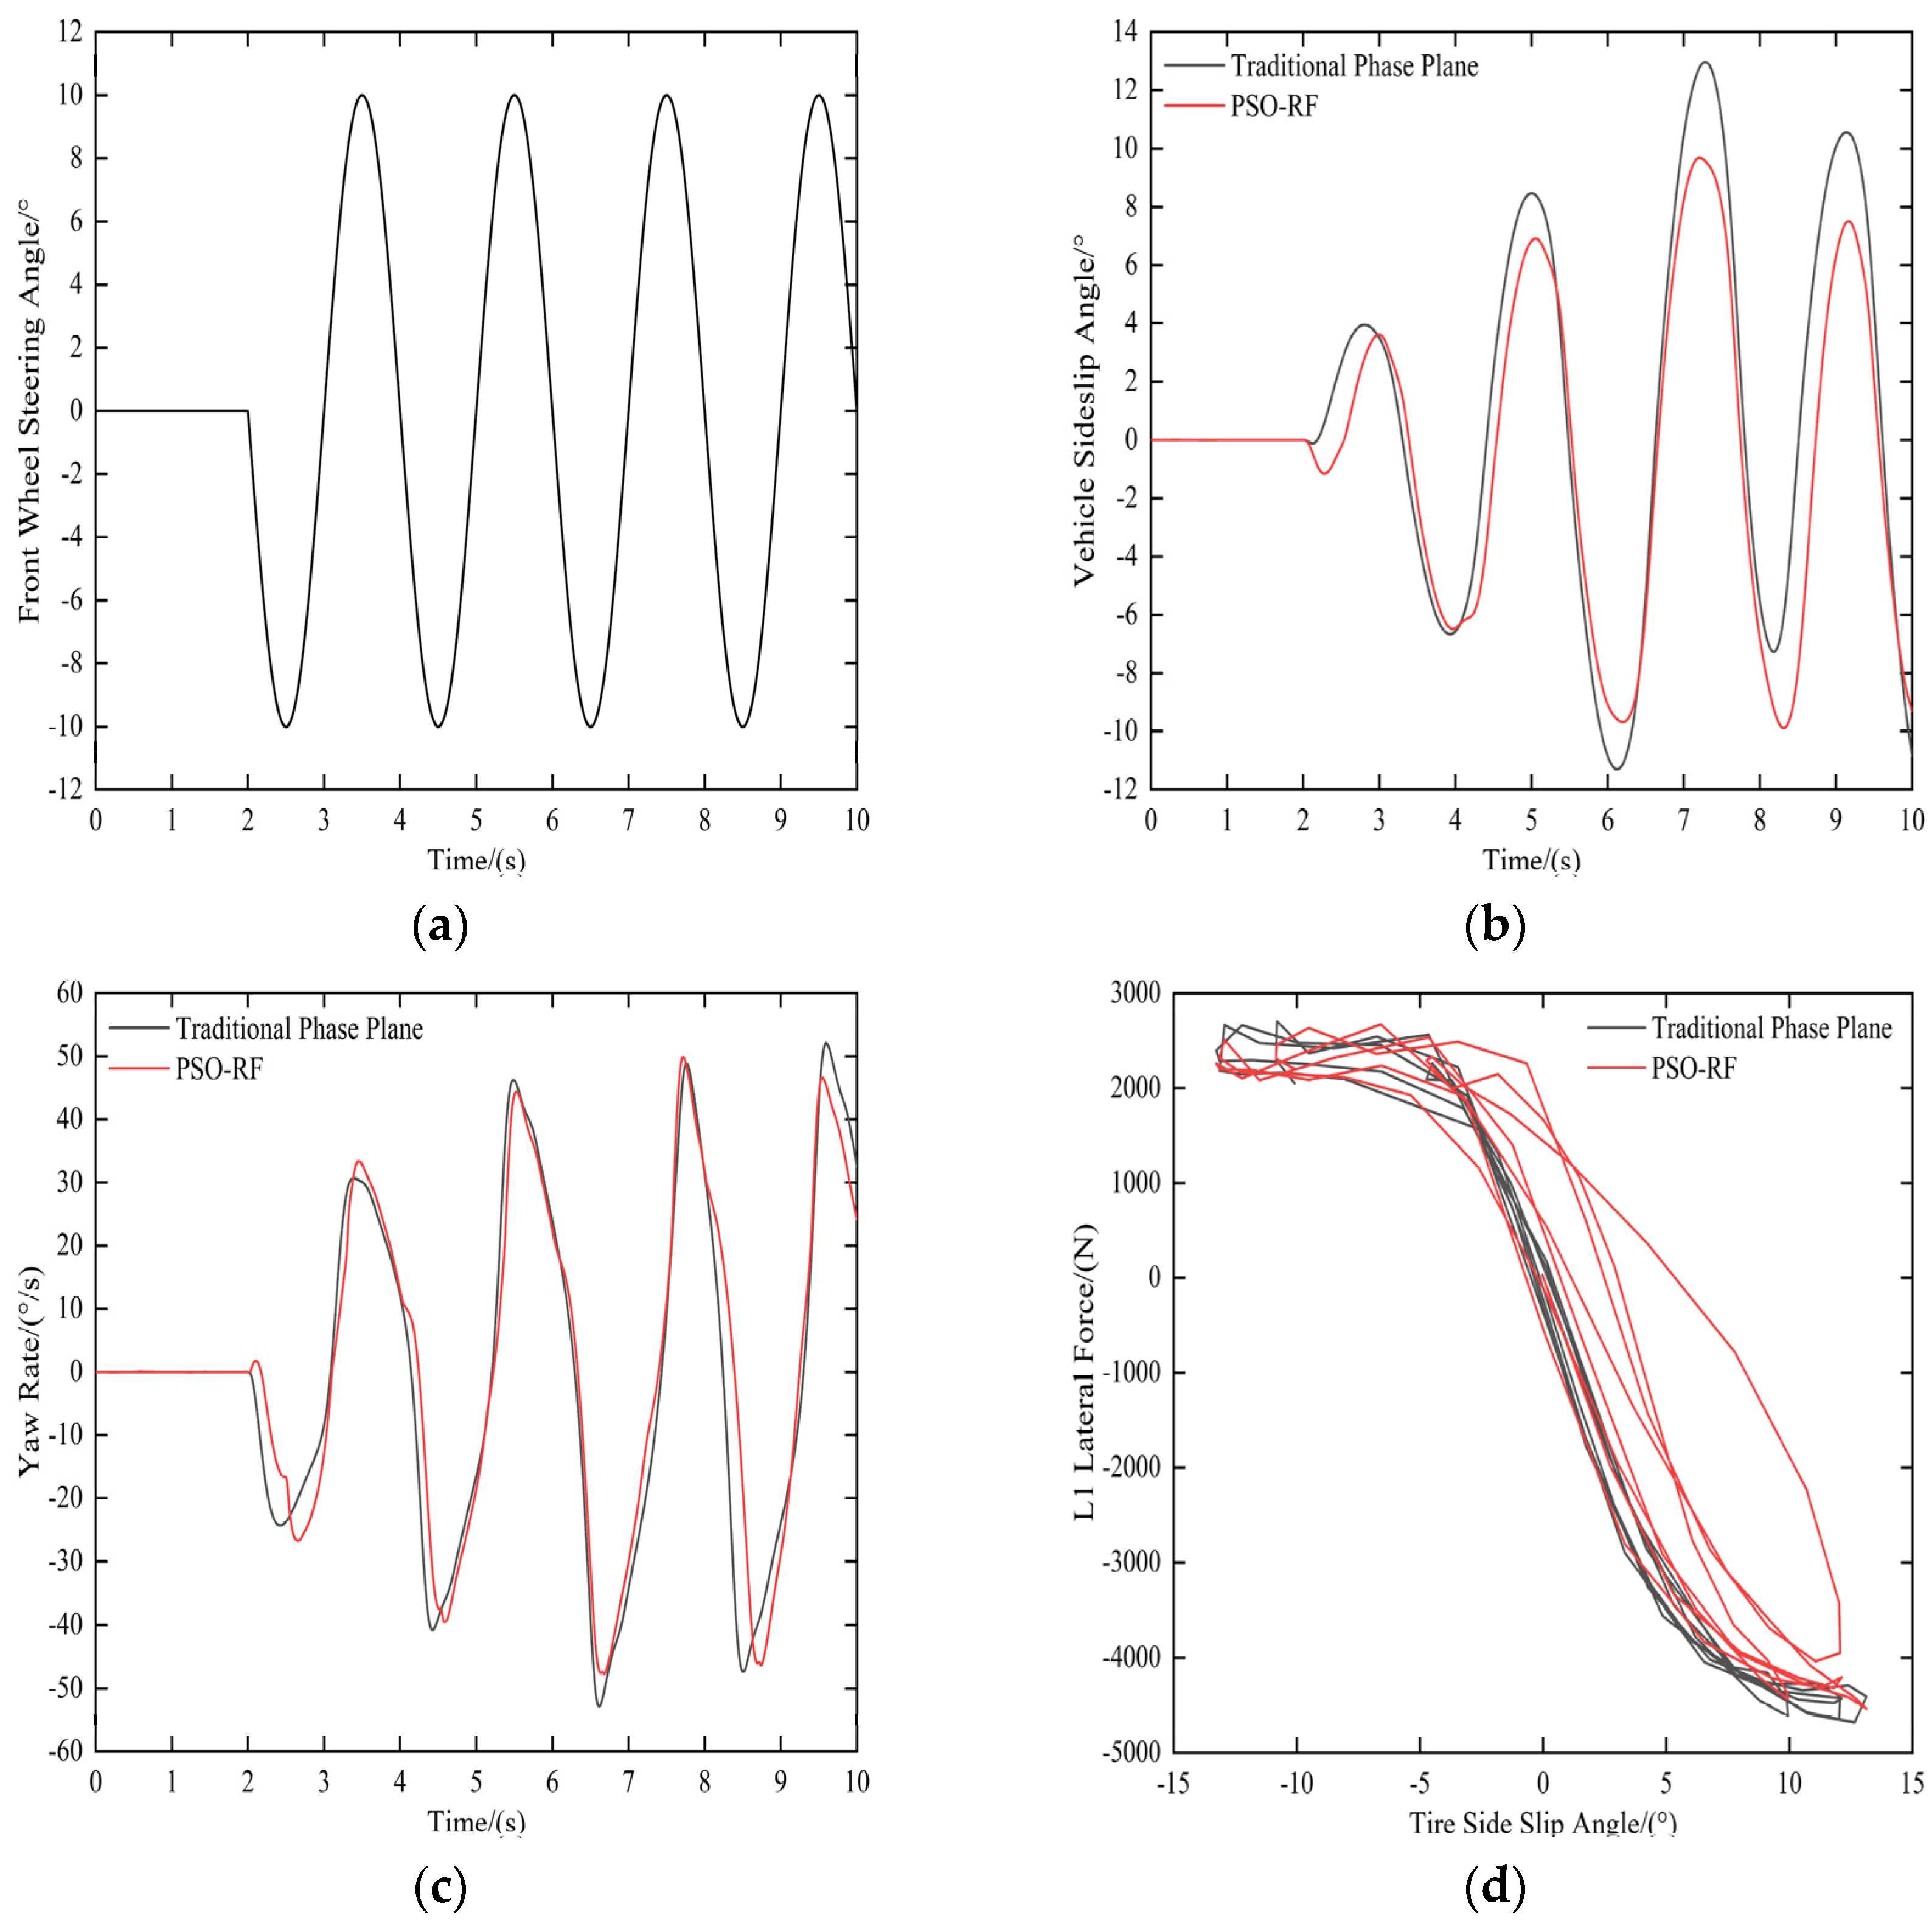
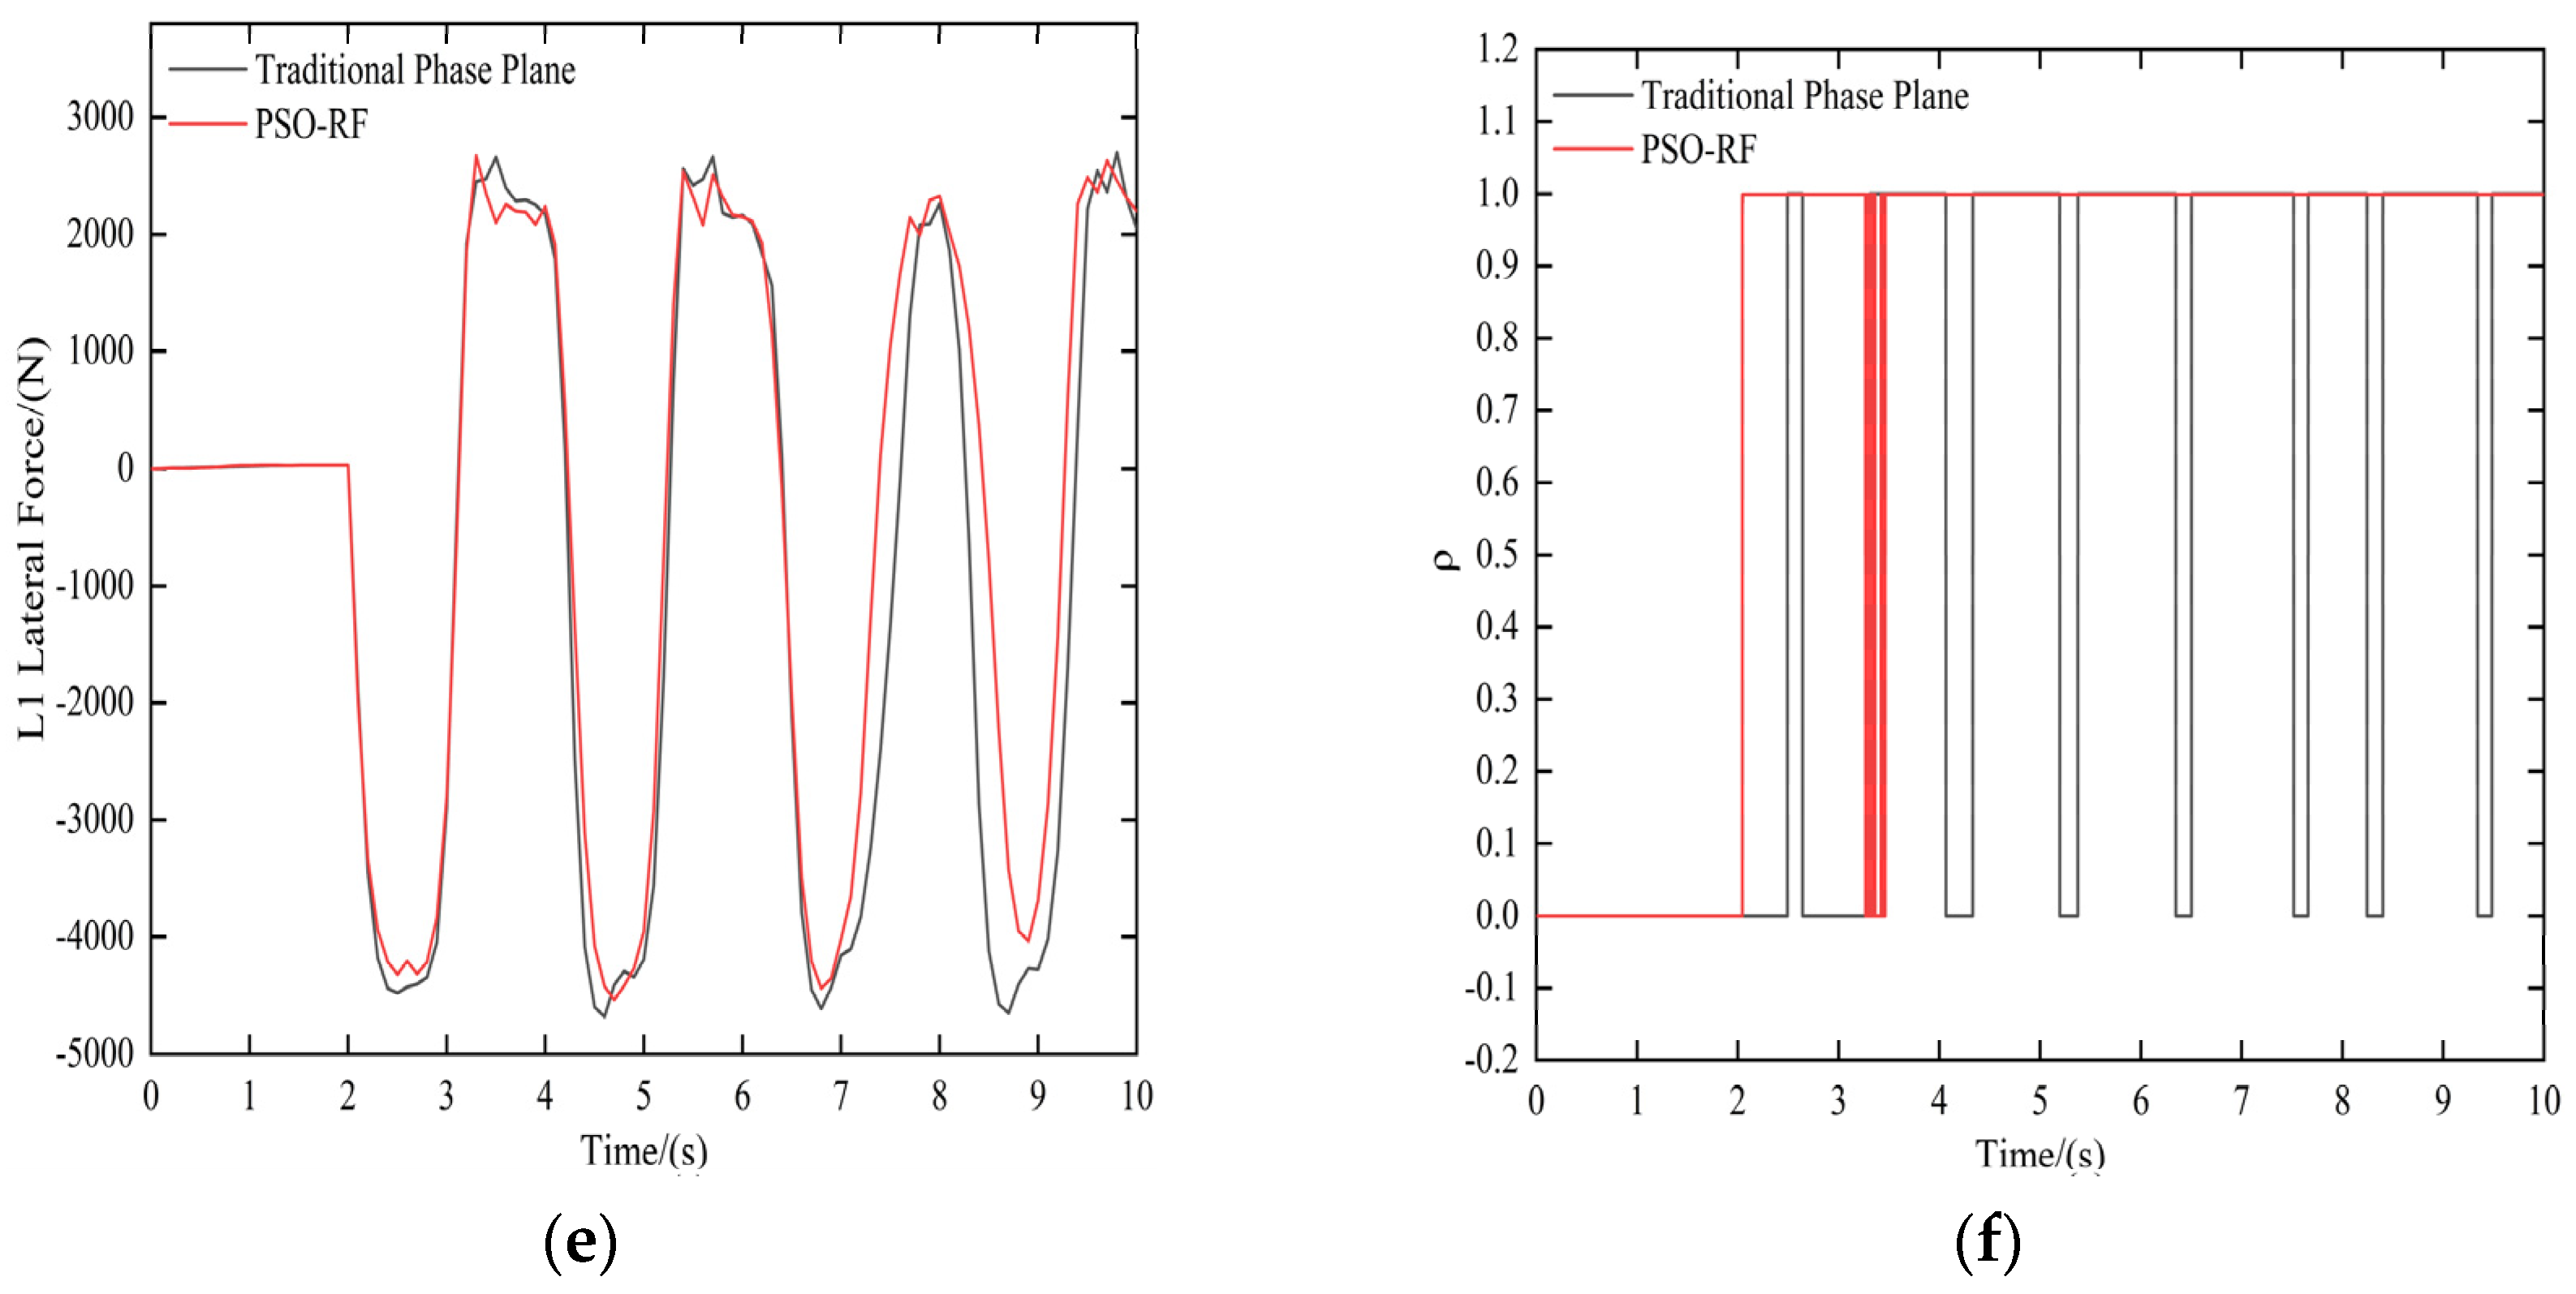
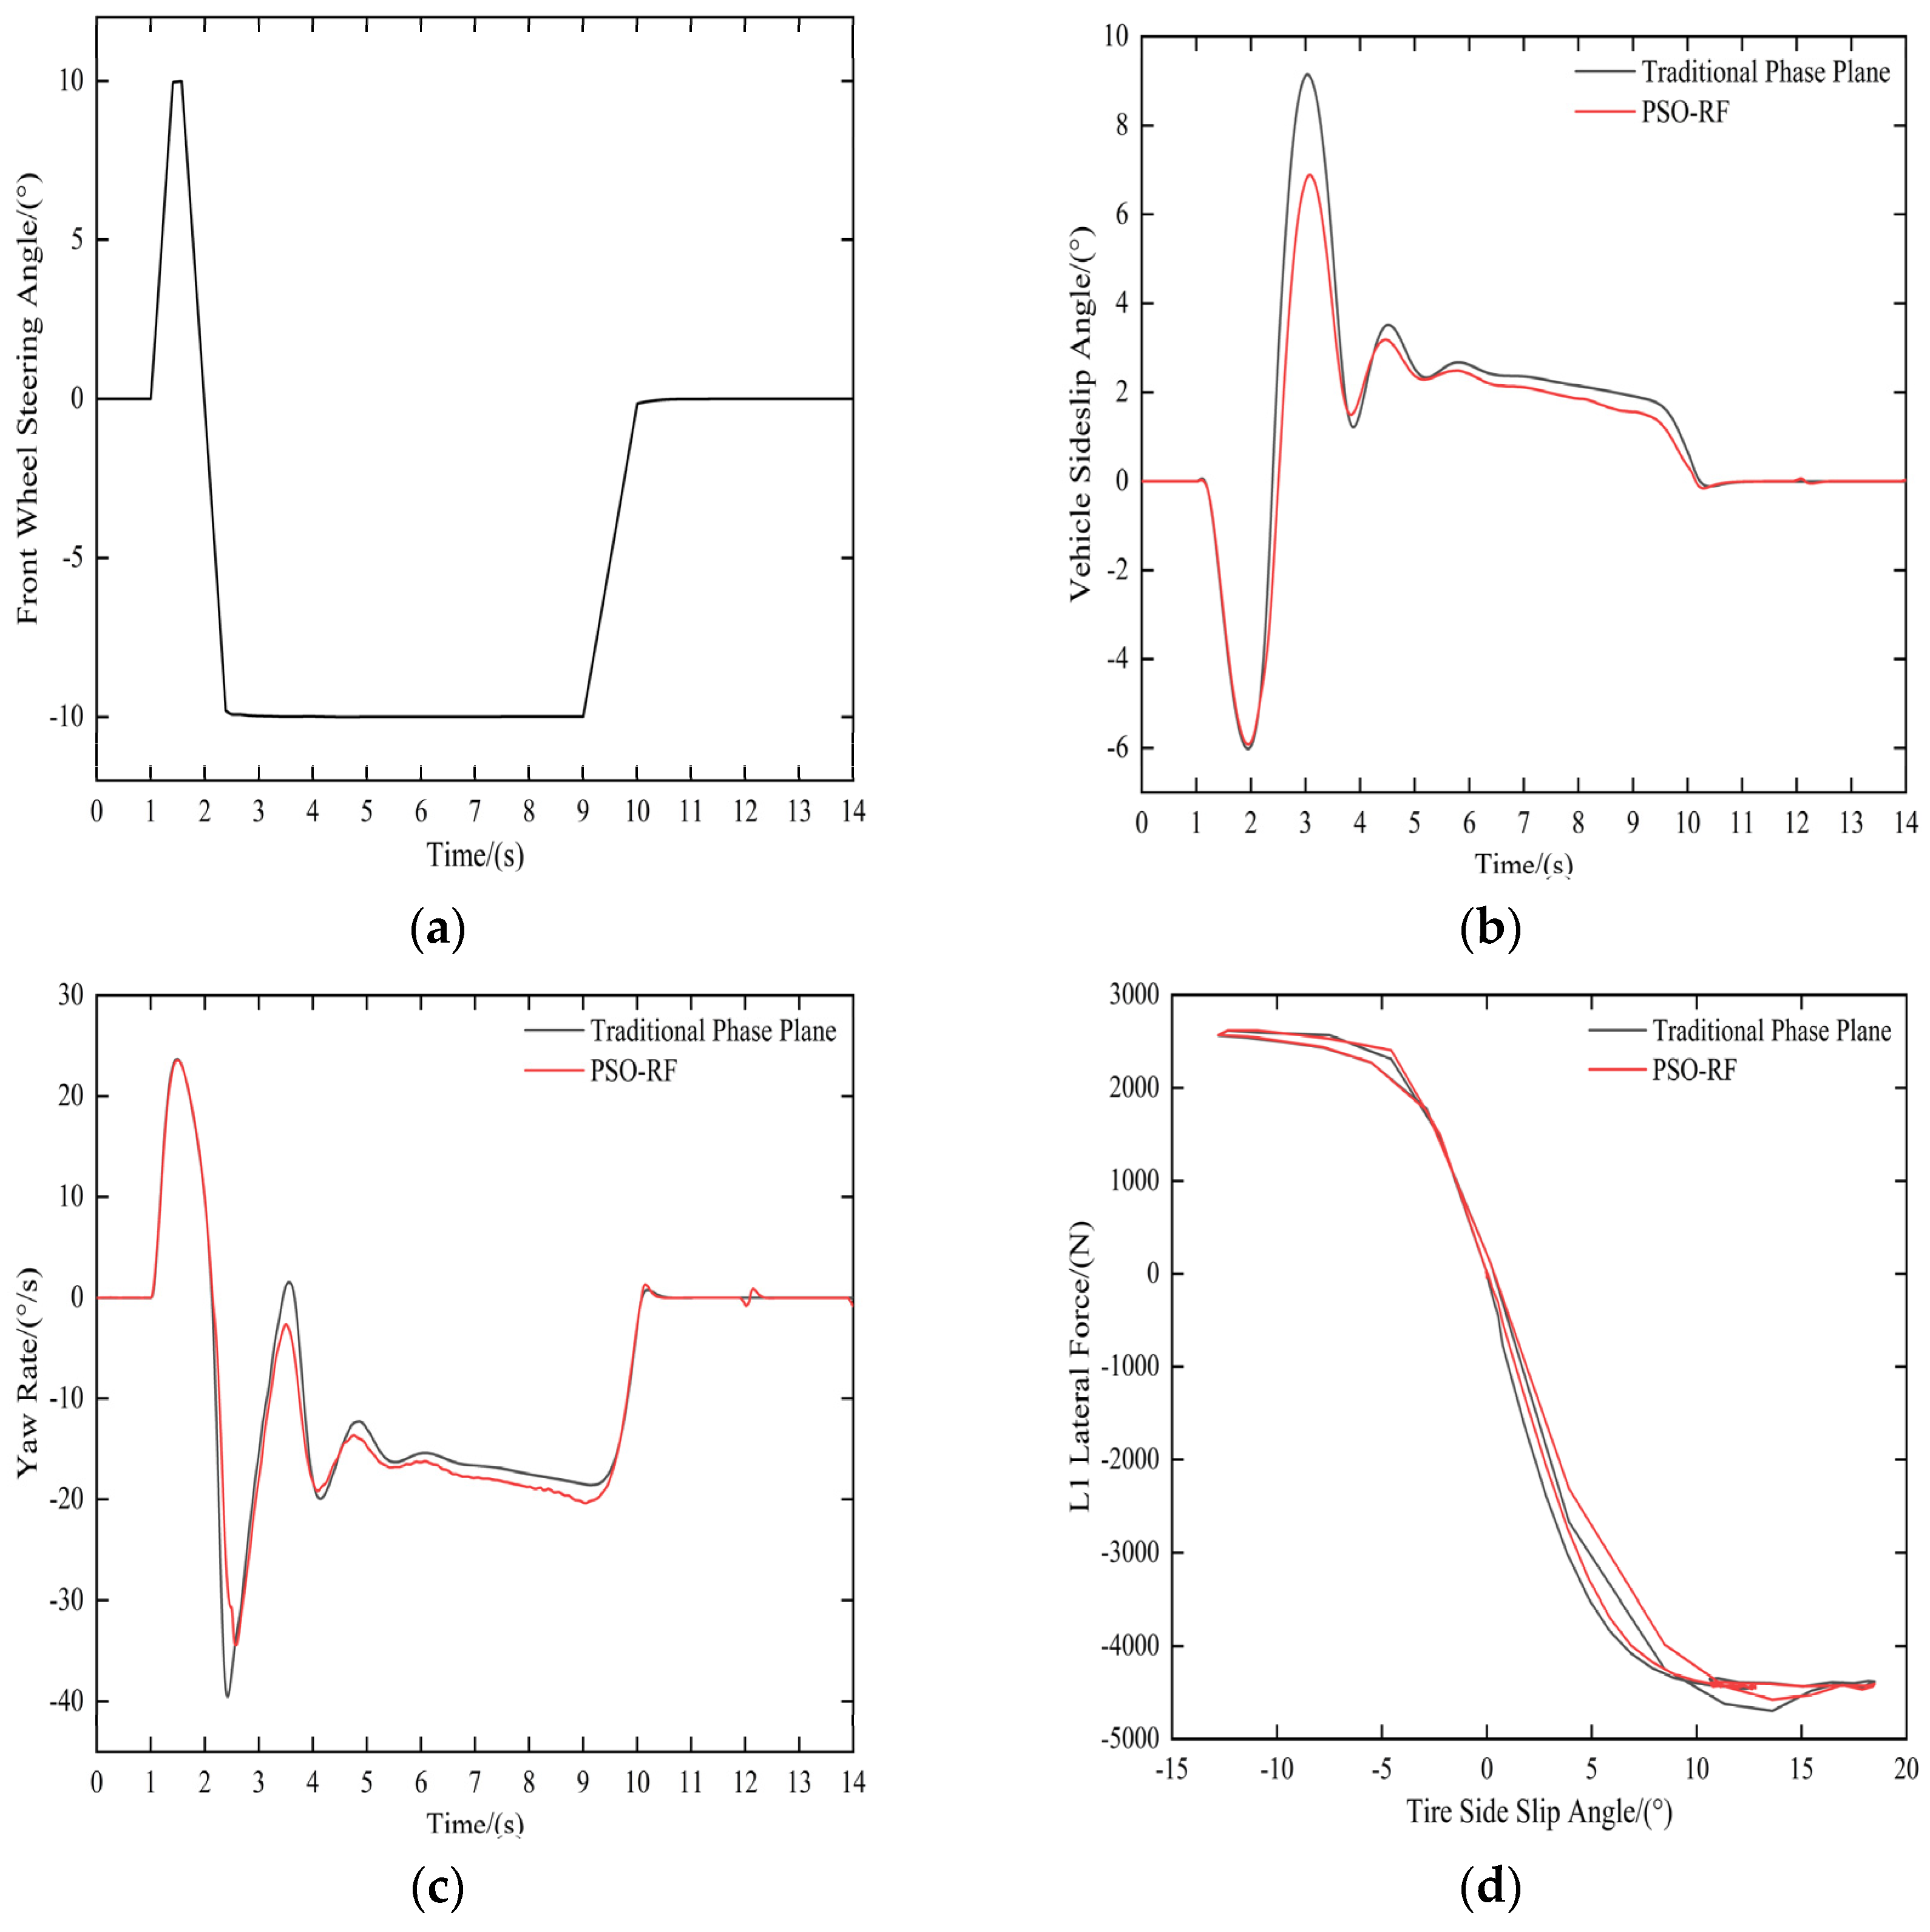
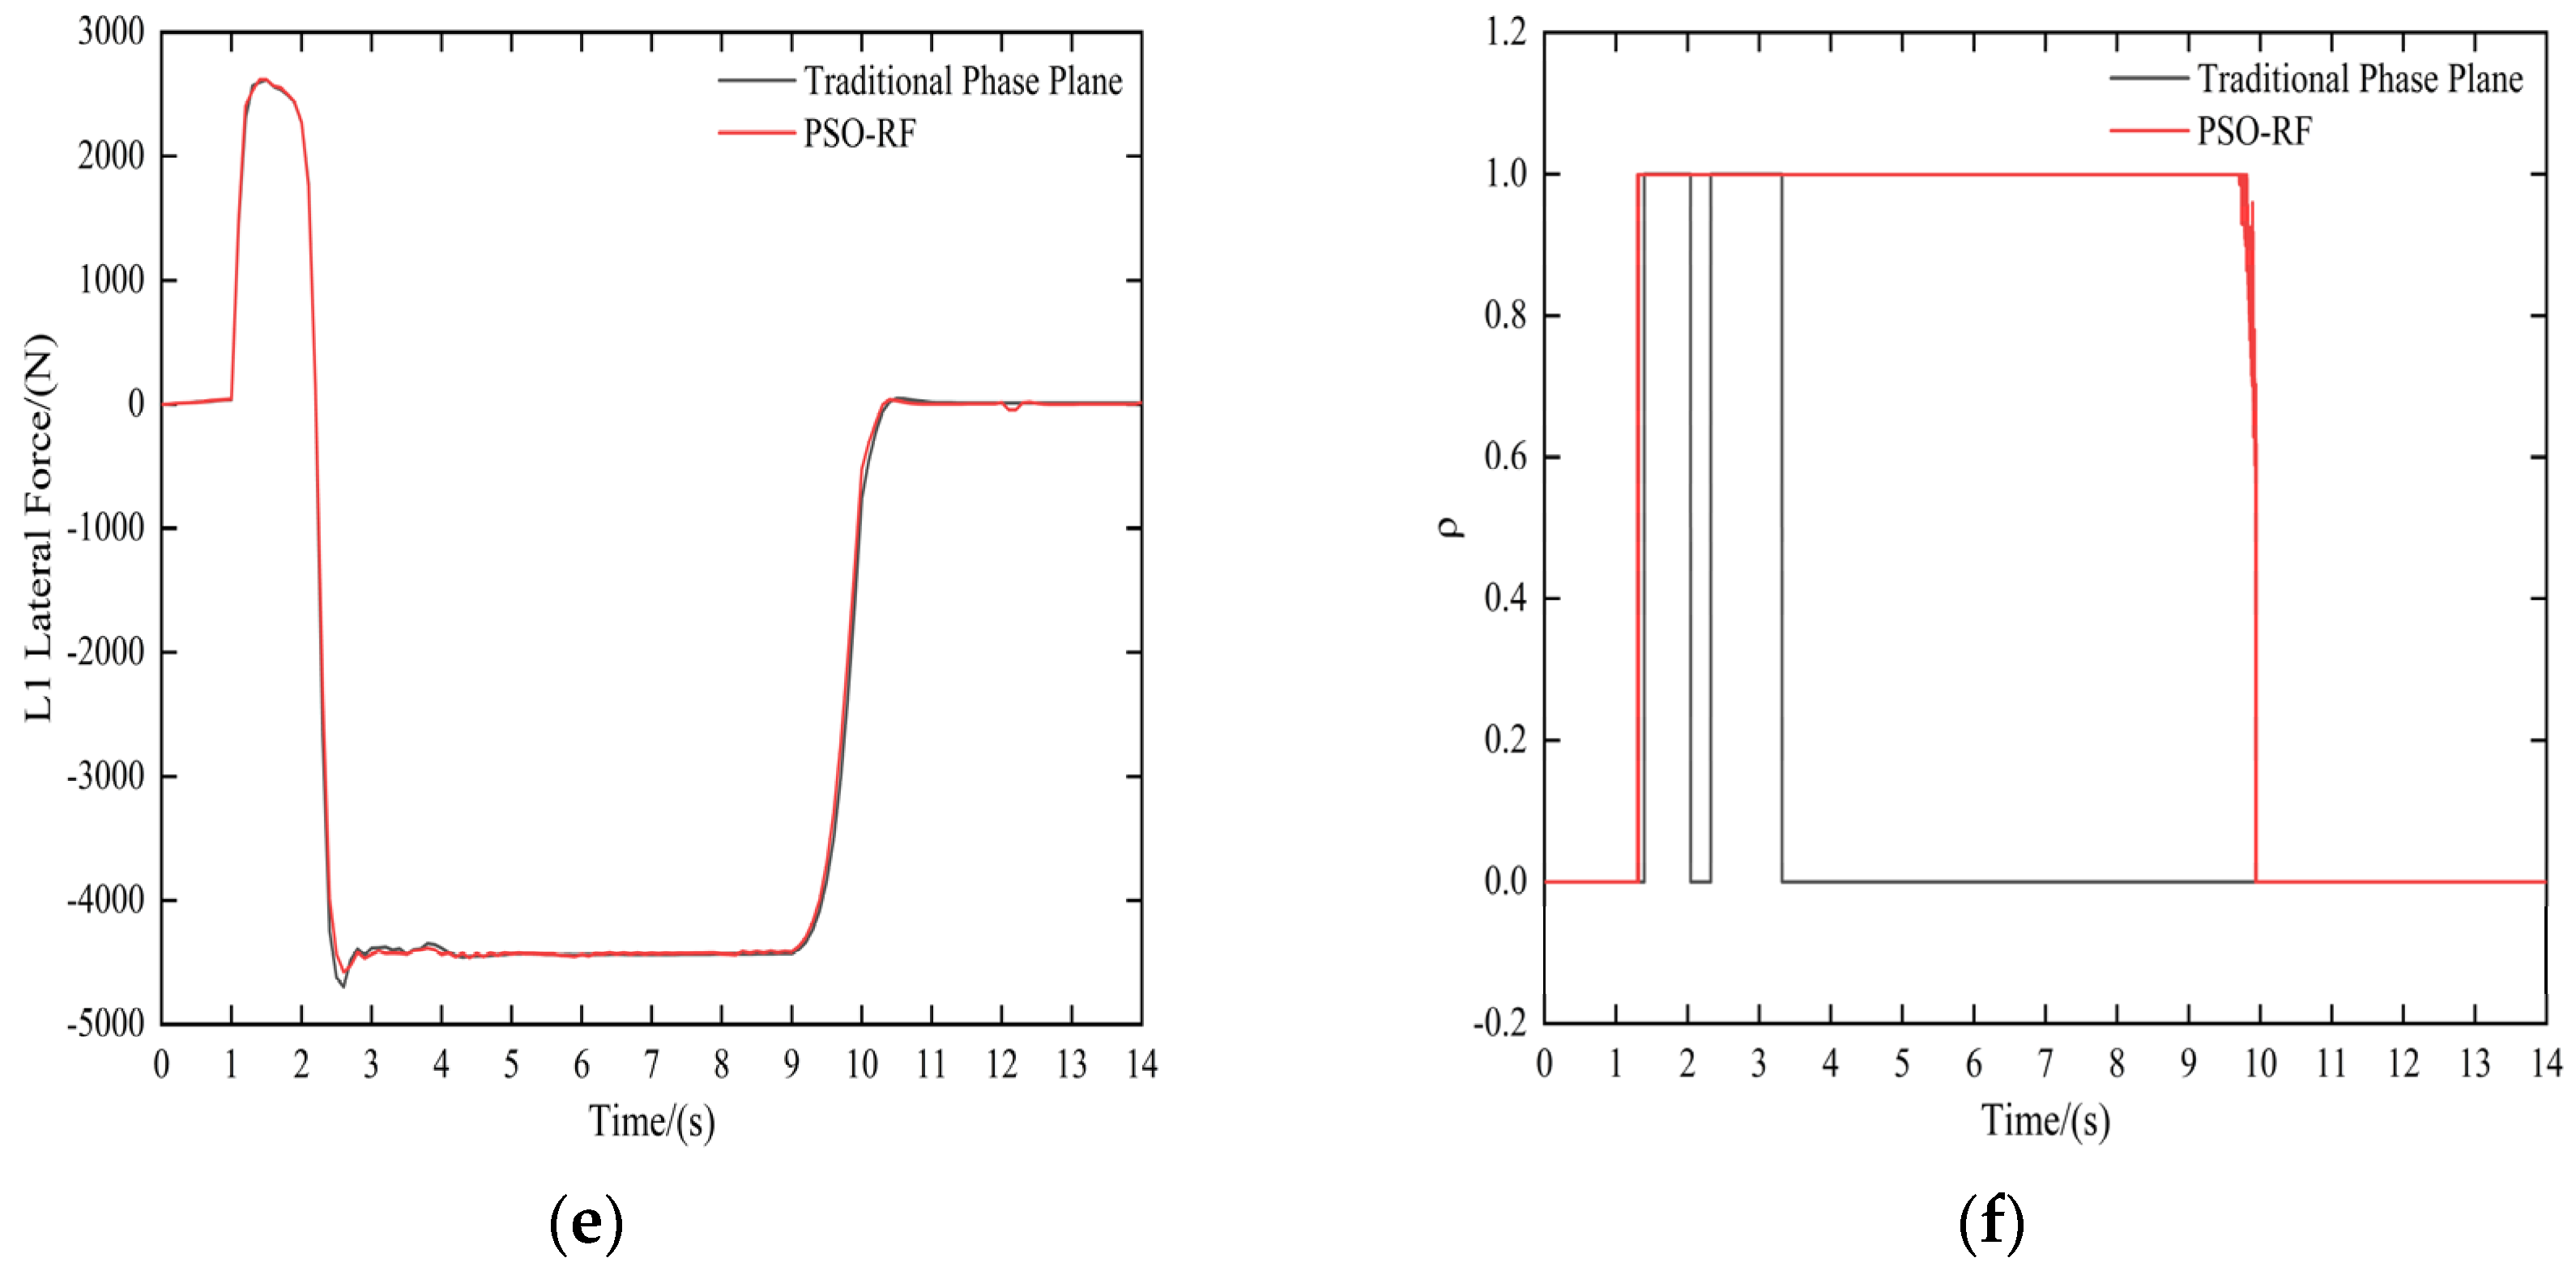
Lateral control is an essential safety control technology for autonomous vehicles, but the effectiveness of lateral control technology relies heavily on the precision of vehicle motion state judgements. In order to achieve accurate judgements of the vehicle motion state and to improve the control effectiveness of vehicle maneuverability and the stability controller, this paper starts with an analysis of phase plane stability. A simulation analysis is conducted to investigate the effect of the vehicle steering angle of the front wheels, the longitudinal velocity, and the tire–road adhesion coefficient on the boundary of the stability area. The stable area of the phase plane was partitioned using the proposed novel quadrilateral method, and we established a stability area regression model using machine learning methods. We analyzed the inherent connection between the lateral tire forces and the principles of vehicle maneuverability and stability control, indirectly combining the characteristics of tire forces with vehicle maneuverability and stability control. An allocation algorithm for maneuverability and stability control was designed. A co-simulation indicates that the vehicle stability controller not only accurately assesses the motion state of the vehicle but also demonstrates a considerably better performance in maneuverability and stability control compared to a controller using the traditional partitioning method of stable regions. The suggested allocation method enhances vehicle maneuverability and stability by enabling a seamless transition between the two and improving the effectiveness of stability control.
Keywords: phase plane; motion state judgment; stability region partition; stability control; machine learning; tire characteristics; sliding mode control phase plane; motion state judgment; stability region partition; stability control; machine learning; tire characteristics; sliding mode control