


Abstract
This paper presents, by taking the elastic string vibration problem as the model problem, the space–time reduced element and the corresponding adaptive analysis algorithm. The solution of the space–time reduced element is extracted from the standard two-dimensional (spatial and temporal dimensions) polynomial element of the Galerkin-type by omitting the highest-degree terms, which serve as a built-in pointwise error estimator for the reduced solution. Taking the reduced solution as the final solution, the proposed adaptivity algorithm can produce solutions from the reduced element that satisfy the user-preset error tolerances in the maximum norm. Theoretical analysis and formulation are presented. Representative numerical examples, including forced vibrations with damping on an elastic foundation and moving load problems, validate the feasibility, effectiveness, and reliability of the proposed method.
1. Introduction
The string vibration equation, also known as the wave equation and equation of axial vibration of an elastic rod, plays a fundamental role in theoretical and numerical analyses of physical and engineering problems. While various numerical methods exist for solving such problems, this paper primarily focuses on the space–time finite element (FE) method of the Galerkin-type and its subsequent adaptive analysis in the maximum norm. The space–time FE method involves discretization in both spatial and temporal dimensions to satisfy respective requirements. For instance, such elements in the temporal dimension should be of the one-step type and unconditionally stable, so that the step-by-step time integration with adaptive time-stepping can be conducted. Since the errors are controlled by the maximum norm, the elements should be continuous in both spatial and temporal dimensions. For adaptive analysis, convenient and reliable pointwise error estimators for both dimensions are required. Therefore, the space–time FE method must address the challenges posed by both space and time FE methods.
In recent years, adaptive FE methods for solving space–time problems have become a research hotspot, mainly involving three approaches [1]. The first approach [2] only adjusts the time-step sizes adaptively with the spatial meshes unchanged. This method is basically to solve a semi-discretized problem generated by the FE method of lines (MOL) and is not truly a fully adaptive approach on two-dimensional space–time domains. The second approach [3] accommodates fully unstructured space–time meshes with discontinuous Galerkin discretization in the temporal dimension. Although theoretically flexible, this method is practically a global approach rather than a step-by-step adaptive analysis in the temporal dimension, leading to reduced computational efficiency. The third approach employs discontinuous Galerkin finite elements in the temporal dimension [4,5,6,7,8,9,10,11,12] and continuous finite elements in the spatial dimension, with most adaptive analyses relying on a unified initial mesh for each time-step. This approach ensures a high convergence rate and reasonable time-step size distribution in the temporal dimension without the need to consider the issue of hanging nodes, which has emerged as the mainstream algorithm for adaptive analysis with space–time elements. However, the low nodal accuracy of discontinuous Galerkin elements and the relaxation of the continuity of the overall FE solutions in the temporal dimension make it difficult to estimate errors in the maximum norm. Other methods, such as moving-mesh techniques for continuous space–time elements [13,14,15], have been proposed but face challenges in complexity and lack comprehensive computational validation of their effectiveness and robustness.
The reduced element is a newly proposed general approach for adaptive FE analysis by the authors of this paper [16,17,18,19]. It is initially proposed for initial value problems (IVPs) [16], especially in dynamic analysis, and then subsequently extended to boundary value problems (BVPs) [17]. Its success in both temporal and spatial adaptivity paves the way for interweaving the one-dimensional (1D) temporal and spatial reduced elements into a two-dimensional (2D) space–time reduced element, effectively resolving the challenges in space–time adaptivity on the whole space–time domain.
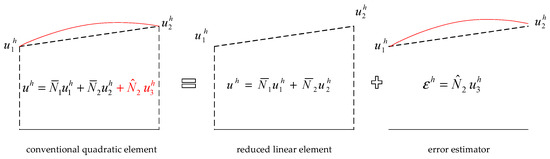
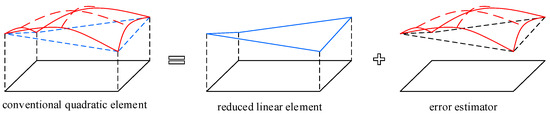
The basic idea of the reduced element is very simple and can be summarized as follows. Supposing the solution for the reduced element of degree m is sought, a conventional FE analysis is first performed using elements of degree . After obtaining the full solution of the conventional elements, the reduced solution is extracted by retaining terms up to degree m, while the highest-degree terms (i.e., degree ) serve as a built-in pointwise error estimator for the reduced solution . In other words, the solution of the conventional element is decomposed into two parts , where represents a reduced solution and is an error estimator for the reduced solution . Figure 1 and Figure 2 illustrate the schematic diagrams of the structures for 1D and 2D reduced linear elements, respectively. By utilizing the “order difference” in accuracy between the full solution and the reduced solution, a built-in error estimator that can be used for pointwise error estimation is readily available, naturally resulting in a maximum-norm-adaptive algorithm using the reduced solution as the final solution.
Figure 1.
Structure of 1D reduced element.
Figure 2.
Structure of 2D reduced element.
The reduced element possesses several advantages, briefly summarized as follows: (1) Unified construction of reduced elements for arbitrary polynomial degrees ; (2) unconditional stability for IVPs across diverse problem types; (3) nodal convergence orders in 1D ordinary differential equations (ODEs) twice those of interior solutions, particularly advantageous for IVPs with long-time domains; (4) nodal accuracy exceeding interior convergence by at least one order, localizing errors to element interiors and significantly improving local refinement reliability; and (5) a built-in maximum norm error estimator enabling adaptive algorithms to meet user-defined error tolerances.
Taking the extended string vibration equation (with damping and an elastic foundation) as the model problem, this paper proposes the space–time reduced element with an effective and reliable adaptive algorithm driven by spatial mesh refinement and time-stepping adjustment controlled by the maximum norm. This paper presents the theoretical analysis and numerical implementation of the space–time reduced elements of degree . To demonstrate the feasibility and effectiveness of this method, several typical numerical examples are presented, covering cases such as initial velocity, initial displacement, abrupt local load, damping, concentrated load, uniform load, and even moving load, for all of which satisfactory results are obtained.
2. Model Problem and Finite Element Strategy
2.1. Model Problem
The problem considered in this paper is focused on the following extended vibrating string equation:
where is the lateral displacement of the string of unit length; , , and are all functions of representing mass, damping, tension of the string and stiffness of an elastic foundation respectively; is load function; and are initial displacement and velocity respectively; and is the upper bound of the time domain. The model problem in Equation (1) corresponds to multiple physical problems, e.g., when and , it is the wave equation and meanwhile it also represents an axial vibration of an elastic rod with being the axial rigidity.
2.2. Strategy of FE Discretization
The strategy of the FE discretization of Equation (1) follows a dimension-by-dimension strategy and comprises three steps:
- Firstly, FE semi-discretization is carried out only in the spatial dimension as done in the finite element method of lines (FEMOL) [18], leading to a system of second-order dynamic equations in ODEs defined on nodal lines in the temporal dimension. In the following sections, the semi-discretized FEMOL element will be simply called ‘space element’.
- Secondly, the second-order FEMOL ODEs are transformed equivalently into a system of the first-order ODEs, which are called the first-order dynamic equations [19]. The reason for the transformation is because for the first-order ODEs, the time elements are unconditionally stable whereas for the second-order ODEs, they are only conditionally stable [19,20,21].
- Thirdly, discretization of the first-order dynamic equations in ODEs by the method proposed in Ref. [16], i.e., by the Galerkin-type time element with adaptive time-stepping for step-by-step time integration [16]. In the following sections, such elements will be called ‘time element’.
In addition, the same polynomial degree is used for discretization in both dimensions, and therefore the space–time element of degree is of rectangular shape with bi-polynomials of degree on it. In the spatial dimension, the mesh adaptivity is done by dividing an unsatisfactory element into two elements in the spatial dimension while in the temporal dimension, the time-stepping adaptivity is done by adjusting the time-step sizes (element lengths) in the temporal dimension.
3. Space–Time Element
3.1. Space Element in Spatial Dimension
To derive the semi-discrete FEMOL ODEs by the Galerkin weak form, define bilinear and linear forms respectively as follows:
Let and denote the trial space and test spaces respectively, formed by functions with required continuity and integrability on . In addition, the trial functions in are required to satisfy the boundary condition and the initial conditions in Equation (1), and the test functions in are required to satisfy . Then the Galerkin method for the model problem in Equation (1) is to find such that
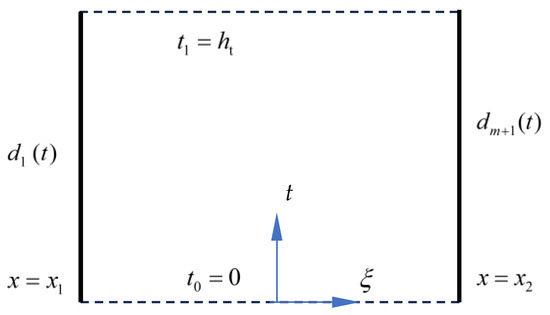
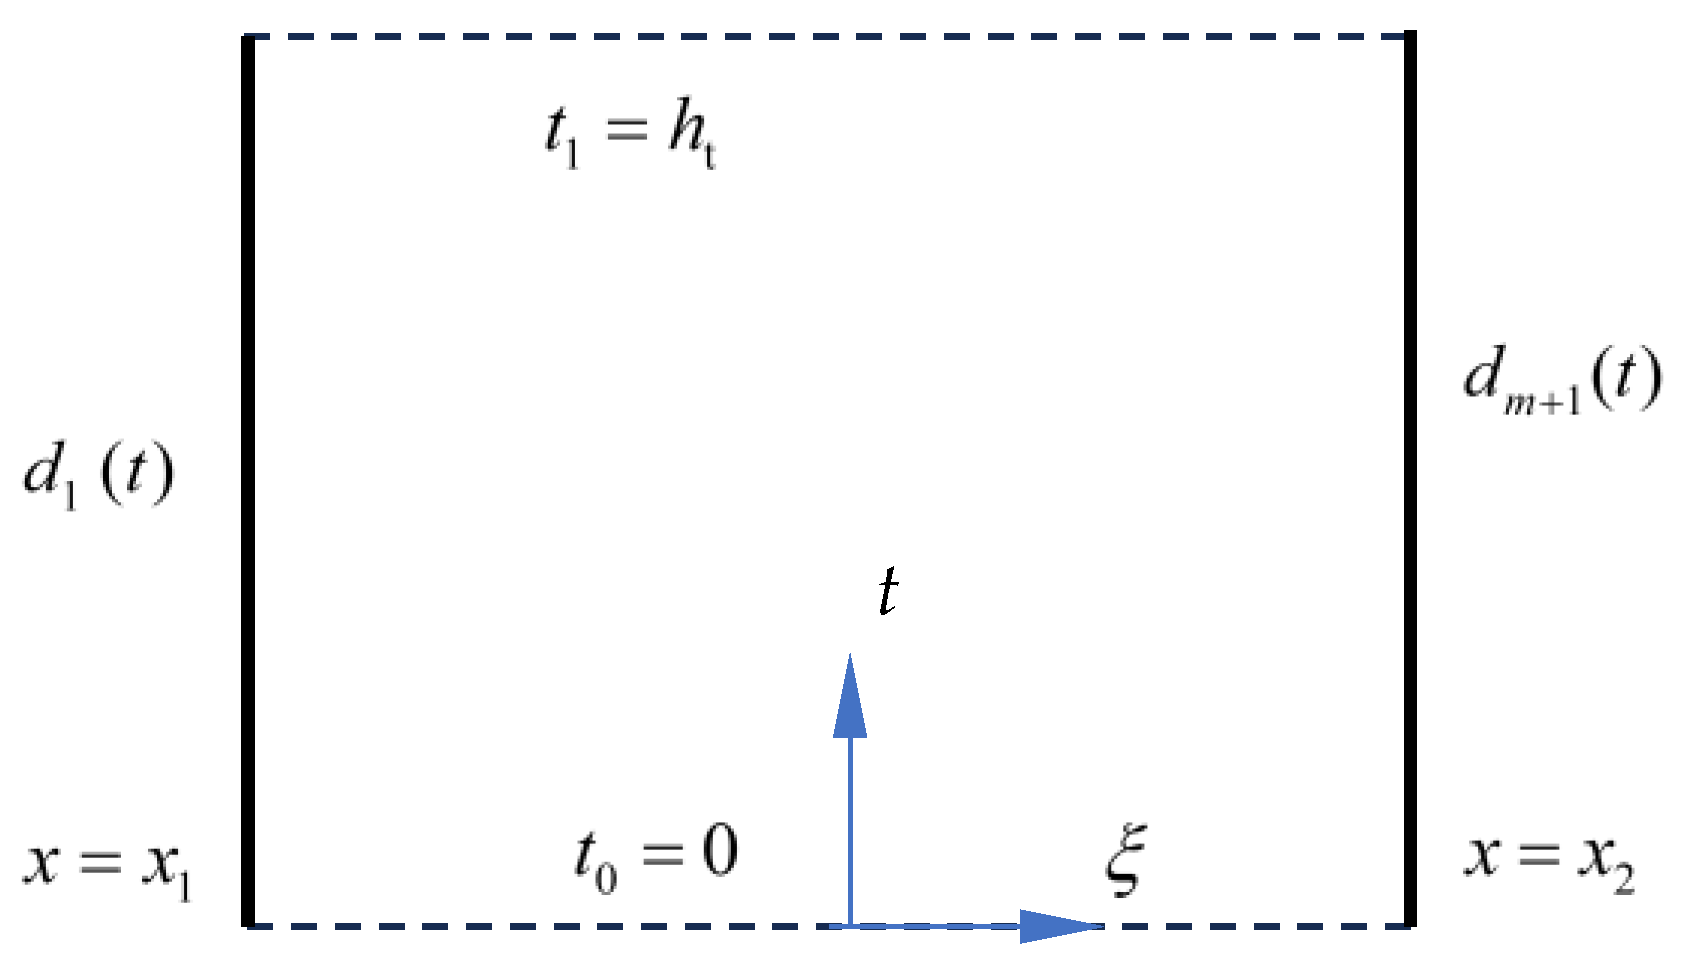
Consider a typical space–time element shown in Figure 3, in which the space element length is and the time-step size (time element length) is . Since the proposed space–time element is of the one-step type in the temporal dimension and the whole solution on the time domain can be obtained in a step-by-step recursive fashion, it suffices to consider only the first time-step as the time domain as shown in Figure 3.
Figure 3.
A typical space–time element.
For the time being, the semi-discrete displacement on the element is modeled by interpolation of the FEMOL type, and the trial function and test function are of the following form by using the hierarchical shape functions of degree :
where
Further, is the standard Legendre polynomial of degree and
It is seen that bubble shape function represents the polynomial term of degree . The hierarchical shape functions are preferable because it greatly facilitates the extraction of the reduced solution, which will be addressed later in this paper.
To derive the FEMOL equations, we put the trial and test functions into vector form
where
Here, will be called the element nodal line displacement vector and can be similarly defined. Substituting the trial and test functions into Equation (2), the semi-discrete bilinear and linear forms for an element e can be obtained:
where the over dot means derivatives respective to time t, i.e., and
Also note that in general the matrices and vectors in Equation (10) are functions of time t. Assembling the matrices and vectors in Equation (10) of all the elements on the current time-step gives the corresponding global ones denoted by the same symbols without the superscript e, i.e., , , and . Then from the global weak form in Equation (3), the following system of second-order FEMOL ODEs in time can be derived
where and are formed with the coefficients of the piecewise interpolation to the corresponding initial conditions. Then the problem has been transformed into a system of standard dynamics equations of multi-degrees-of-freedom (MDOF).
3.2. Time Element in Temporal Dimension
By introducing a velocity vector defined on nodal lines, the second-order ODEs in Equation (11) can be equivalently transformed into a system of first-order ODEs as follows:
where
Equation (12) is a standard first-order IVP, and the corresponding conventional Galerkin element can be constructed following the same procedure in Ref. [16], which is briefly described in the following.
For a typical time element (time-step) of degree , the trial functions in and in on the i-th element nodal line are modeled using the same hierarchical shape functions of degree as
or in vector form as
where
The associated test functions simply use the standard Legendre polynomials as the shape functions. Thus, the trial function vector and the associated test function vector can be expressed as
where
with being identity matrix of order in and in .
Let denote the trial space formed by all the trial function vectors on the time element which satisfy the initial condition in Equation (12). Let denote the associated test space formed by all the test function vectors . Then the Galerkin weak solution based on the above FE formulation for the IVP in Equation (12) is to find such that
from which the needed matrix equation for the time element can be derived.
With obtained, the FE solution and on a typical space–time element, although obtained in a dimension-by-dimension fashion, can be expressed in the form of bi-polynomials of degree as follows:
3.3. The Reduced Element
Taking the displacement solution as an example, the velocity solution can be similarly handled. Let denote the FE solution of the space–time element of degree , which hereinafter will be simply called the ‘full solution’. Also let denote the associated solution of the reduced element of degree , which will be simply called the ‘reduced solution’. The subscript ‘R’ represents ‘reduced’.
After obtaining the FE solution , it can be decomposed into two parts: an error term from the highest polynomial degree (e.g., terms containing and ) and a reduced solution from the remaining terms with lower polynomial degrees (e.g., degrees up to ), i.e.,
It follows from Equation (20) that the reduced solution and error terms can be simply expressed as
It is seen that using hierarchical shape functions makes the decomposition of the conventional FE solution extremely easy. As defined above, is the reduced solution of degree and serves as a pointwise error estimator for on the current element.
Similarly, the reduced solution and on the i-th element nodal line can also be readily extracted as
3.4. Error Analysis
To analyze the error in the reduced solution , it is easy to see that
Since the full solution of degree is a conventional FE solution, it follows from the FE error estimate [22] that the first term in Equation (24) is on space–time elements and at nodes as well. And the error of the second term in Equation (24) is purely a polynomial interpolation error on the element level, which is known to be of [22]. Thus, it is concluded that
which is one order lower than the full solution. This order difference has established sound theoretical justification for the validity of the error estimator .
4. Adaptivity Algorithms
4.1. Objective of Adaptivity
The ultimate objective of the adaptive analysis in this paper is to find an optimal mesh, such that the reduced solution of degree satisfies the user-specified tolerance on each element in the maximum norm:
Since the exact solution is generally unknown, the full order solution of degree is used to replace for the error checking and then Equation (26) becomes
Note that since the velocity may often be discontinuous or even singular in the temporal dimension for quite a large number of problems, the present algorithm only adaptively controls the errors of the displacement .
Also, before Equation (27) is satisfied on each space–time element, we first require the nodal line displacements to satisfy [16]
where the lower and upper bounds are simply taken as , as suggested in Refs. [16,19]. We comment that the lower bound is to avoid redundant accuracy and repeated changes in time-step sizes, and the upper bound is to allow some room for the computed errors to slightly exceed the preset tolerance for long time domains. Again, the present algorithm does not impose error controls on the nodal line velocities . Note that is not used in calculation of and hence does not directly affect the accuracy of .
For convenience, let and denote the estimated error ratio and true error ratio defined respectively by
with the corresponding maximum error ratios being
By introducing the definition of error ratios, it is easy to check whether the final solution satisfies the pre-specified accuracy requirement or not. If the final results satisfy , then the adaptive analysis achieves full success, and according to Refs. [23,24], the successful estimated error allows for a 20% fluctuation, which means that, in terms of the error ratio, if or thereabouts, then the adaptive analysis is also considered to be valid.
4.2. Error Calculations
Although there are nodal line solutions on an element, the error calculation of Equation (28) is very simple and straightforward
where the maximum value of can be calculated in advance without the need for pointwise searching, e.g.,
For the error of on the whole space–time element, closed forms of maximum error may not be readily available, and the errors can be calculated numerically at an regular grid point on the element and then the maximum value can be searched for. Usually, each dimension is divided into 12 uniform segments (i.e., ), which is sufficient.
4.3. Treatment of Initial Conditions
For the prescribed initial displacement , adaptive piecewise polynomial interpolations of degree are used to obtain such initial condition that satisfy
To achieve this, starting from an initial coarse mesh provided by the user in the space domain , a piecewise polynomial interpolation is conducted, and then if Equation (33) is violated on any intervals, the interval is divided into two sub-intervals and the process is repeated until Equation (33) is satisfied, as a result of which an initial mesh for the spatial dimension is obtained.
4.4. Mesh Adaptivity
4.4.1. Time-Step Size Adjustment
After each FE run, we first check if the time-step size (element length ) is acceptable. If for any nodal lines in the temporal dimension, Equation (28) is not satisfied, then a new element length is calculated by the formula proposed in Ref. [16] as follows:
where is the current element size and is a safety factor which is set as in this paper. For the new , another FE run is carried out and the process is repeated until Equation (28) is satisfied.
For completeness, we give Equation (34) a brief explanation. Suppose with time-step size , an FE solution with element degree is obtained. According to Ref. [21], the maximum error is bounded . With Integral Mean Value theorem, we have . This makes the above equation change to , from which the constant can be calculated. Now the new can be found from the requirement of , which leads to Equation (34).
4.4.2. Spatial Mesh Refinement
Then we check if the spatial mesh is acceptable. If for any elements on the current time-step, Equation (27) is not satisfied, we simply divide this element into two sub-elements by bisecting so that becomes . After a new mesh is generated in the spatial dimension, another FE run is conducted. The above process is repeated until all elements on the current time-step satisfy the error tolerance pointwisely.
4.5. Hanging Nodes
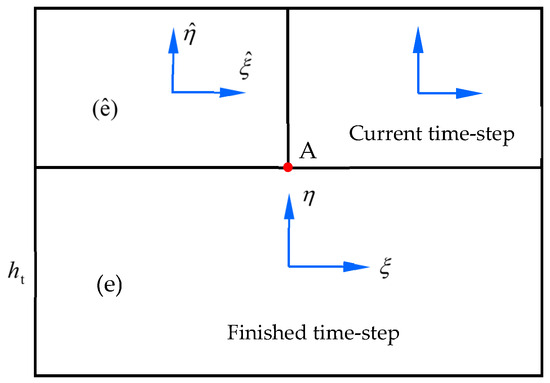
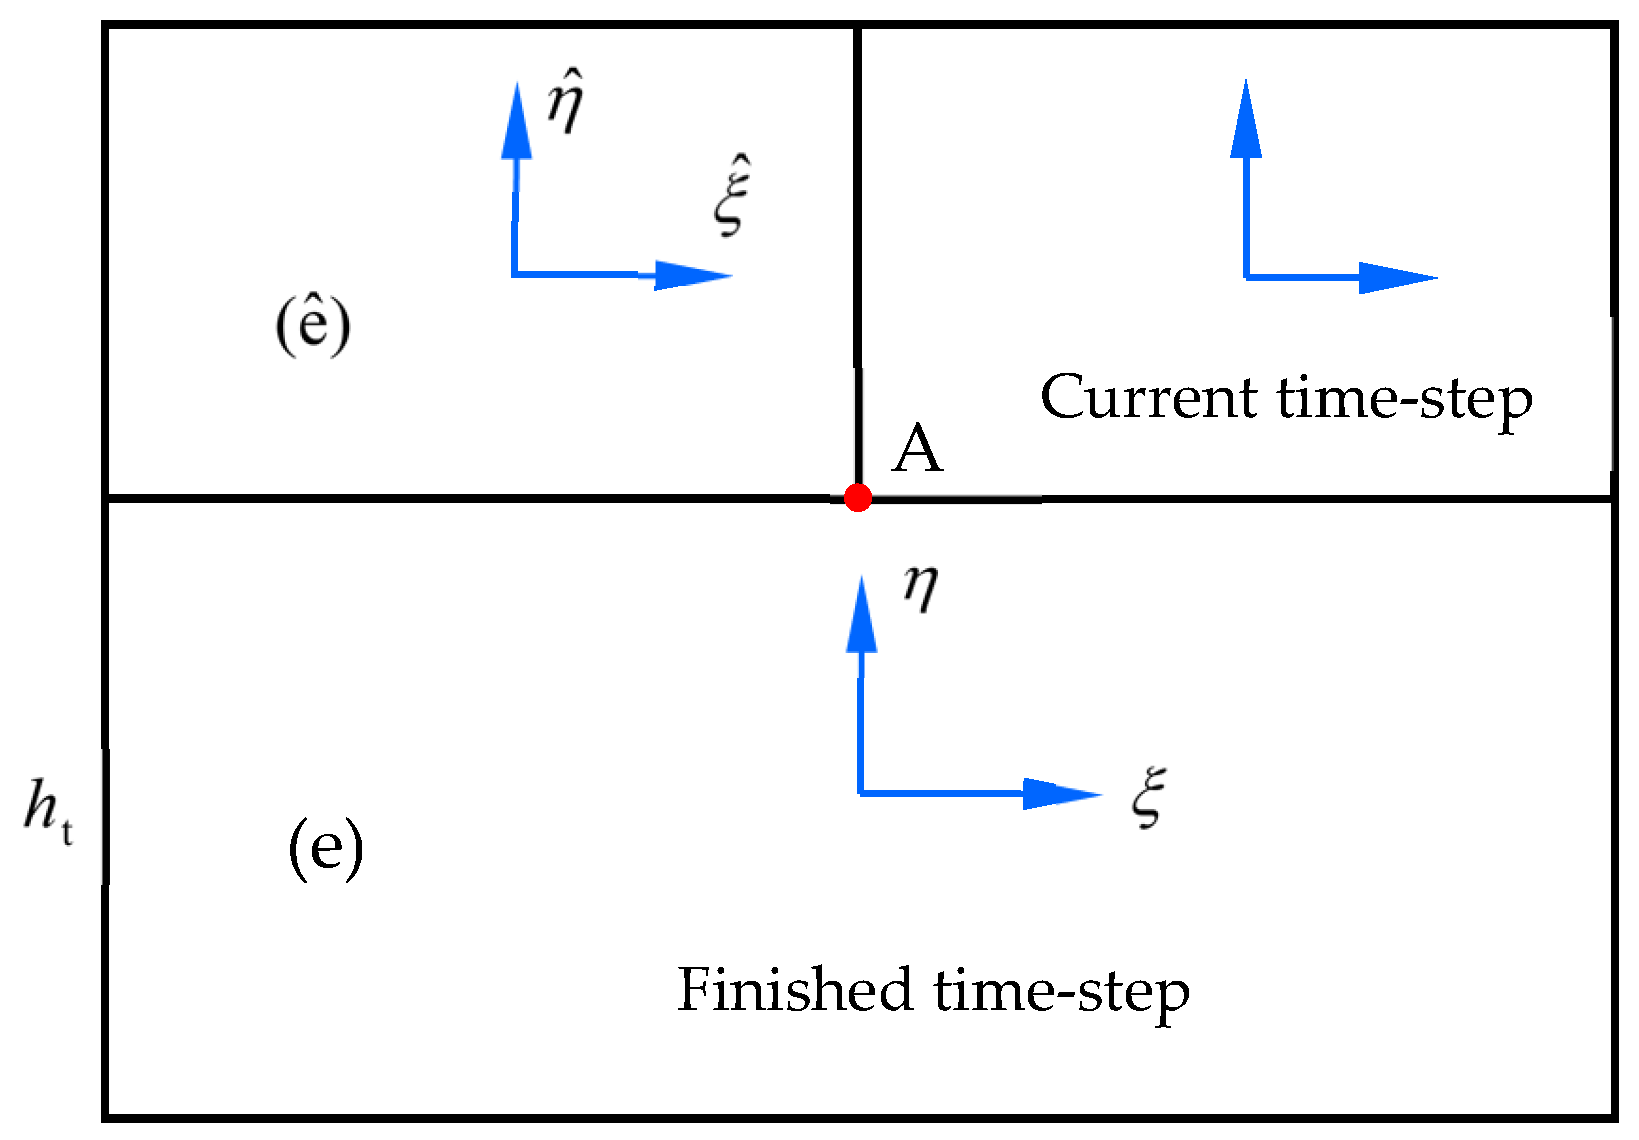
The above mesh adaptivity strategy may generate hanging nodes like point A in Figure 4. Since the present algorithm is a type of step-by-step integration in time, the FE solution on the upper side of the finished time-step in Figure 4 is known and serves as the initial conditions (like and ) for the current time-step. Then the usual piecewise polynomial interpolation of degree m can be done to keep the conforming property for both the full solution and the reduced solution.
Figure 4.
Local mesh with hanging nodes.
4.6. Backtracking
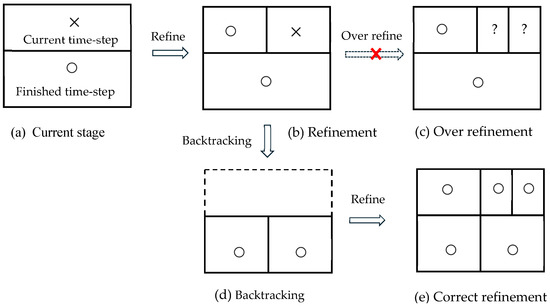
For simplicity and efficiency, at most two hanging elements are allowed to be hung onto a single side of a normal element, otherwise the normal element is to be further bisected into two in a backtracking process. To be more specific, consider the local mesh refinement shown in Figure 5 where the elements that satisfy the error tolerance are denoted by “O”, or otherwise by “X”. Figure 5a is the initial mesh where the upper element needs to be refined. Normal refinement leads to the mesh in Figure 5b, where the upper-right element requires further refinement, which would yield the mesh in Figure 5c and is not accepted since in that case there will be three hanging elements hanging on a single side of the normal element. Then the algorithm will take a step back to the already finished step, refine the overburden element and then proceed. Although this backtracking process may cause slightly redundant accuracy for the normal element, it provides better initial conditions for the upper elements and meanwhile makes the space–time mesh more structured.
Figure 5.
Local mesh with backtracking.
4.7. Adaptivity Algorithm
The adaptivity algorithm for the space–time reduced element approach can be briefly summarized as follows:
- Specify tolerance , the degree m of the reduced element;
- Generate an initial mesh by adaptive interpolation to (Section 4.3) and assign an initial time-step size ;
- Generate FEMOL matrices and vector , , and (Equation (10)) using the space element of degree and form the first-order IVP in ODEs (Equation (12));
- Solve the first-order ODEs in Equation (12) by the time element of degree with adaptive time-step sizes until all the nodal line solutions satisfy Equation (28) [16], and then obtain the full solution and reduced solution on each nodal line with a new time-step size ;
- For the current time-step, check if each space–time element satisfies Equation (27);
- If Equation (27) is satisfied, then move to the next time-step with the current spatial mesh and time-step as the initial mesh and time-step , and then return to Step 3;
- If Equation (27) is not satisfied by any elements, bisect them in the spatial dimension and then check whether backtracking is needed;
- If backtracking is unnecessary, return to Step 3;
- If backtracking is required, return to the previous time-step and return to Step 3;
- The above procedure is repeated until reaching the end of the time domain .
Note that the present paper employed the more stringent maximum norm rather than the more commonly used energy norm employed in most adaptive analyses. Numerous numerical experiments show that, in most cases, satisfaction of Equation (27) would indeed make Equation (26) also satisfied.
5. Numerical Examples
In this section, representative numerical examples are given to test the proposed algorithm. The above algorithm has been coded in Fortran 90 and implemented on a PC. In the following, the element degree exclusively refers to the polynomial degree used in the reduced element. In the practical computation, various tolerances ranging from to are adopted, and the linear () to cubic () reduced elements are employed for the presentation although other degreed elements have also been tested. For all the examples, the initial time-step size is taken as .
5.1. An Illustrative Example
This test problem is Example 5.2 in Ref. [1]. In this example, the first two time-steps of the adaptive procedure are given in detail and then full results from elements of different degrees and different error tolerances are presented. The problem is defined as follows:
with the exact solution being . The tolerance is set , and the initial time-step size (time element length) is . Since the solution is symmetric, only half space domain is used in computation. The linear reduced elements () is used as the final solution and the initial number of elements of the spatial mesh is one. Then from Equation (4), the quadratic trial function of the full element for FEMOL is
The corresponding element matrices and vector of FEMOL in Equation (10) can be derived as
Since the present algorithm imposes error controls on only, the adaptive interpolation to proves that a single space element is sufficient and then the initial value vectors are
Introducing the boundary condition, the second-order FEMOL ODEs can be derived
Thus, the first-order ODEs in Equation (12) can be formed. Then the trial function vector and test function vector for the time element are respectively as follows:
Note that the components of are replaced by the initial values in Equation (38). Following the process described in Ref. [16], the FE solutions for the nodal displacement vectors are
Without extracting the reduced solution on the nodal lines, the errors can be directly calculated using Equations (31) and (32) as follows:
Thus, by Equation (28), the maximum estimated error ratio for the time element is and therefore the current time-step size needs to be adjusted. A new step size is predicted using Equation (34) as follows:
Then repeating the FE process for the time elements with the new yields a new set of nodal displacement vectors,
and the corresponding estimated maximum error ratio is 0.714, which satisfies the requirement in Equation (28). Therefore, the full solution of the displacement is
Making a linear interpolation to yields the reduced solution
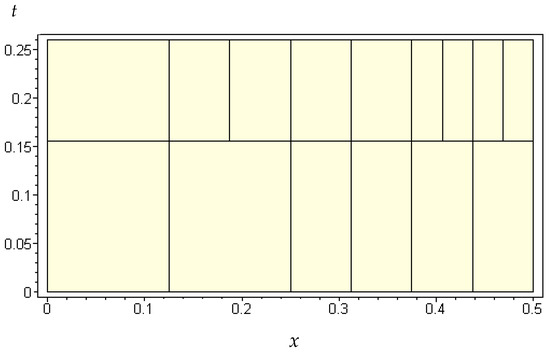
It is not difficult to find out that the estimated maximum error ratio in the entire space–time element is , which fails to meet the error tolerance. Therefore, the element should be divided into two. The subsequent iterative process is summarized in Table 1 and the finished mesh is shown in Figure 6.
Table 1.
Adaptive process of the first time-step.
Figure 6.
The mesh of the first two time-steps of the illustrative example.
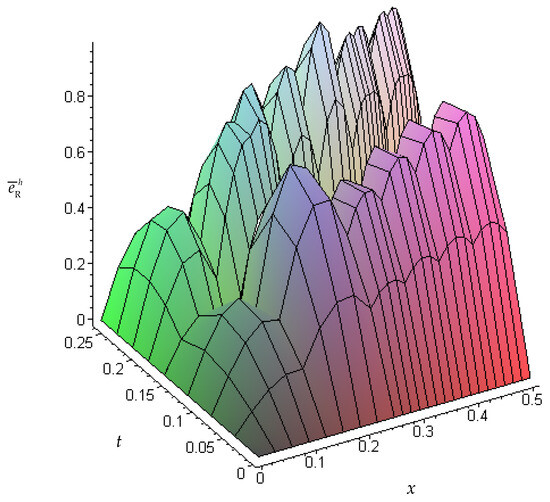
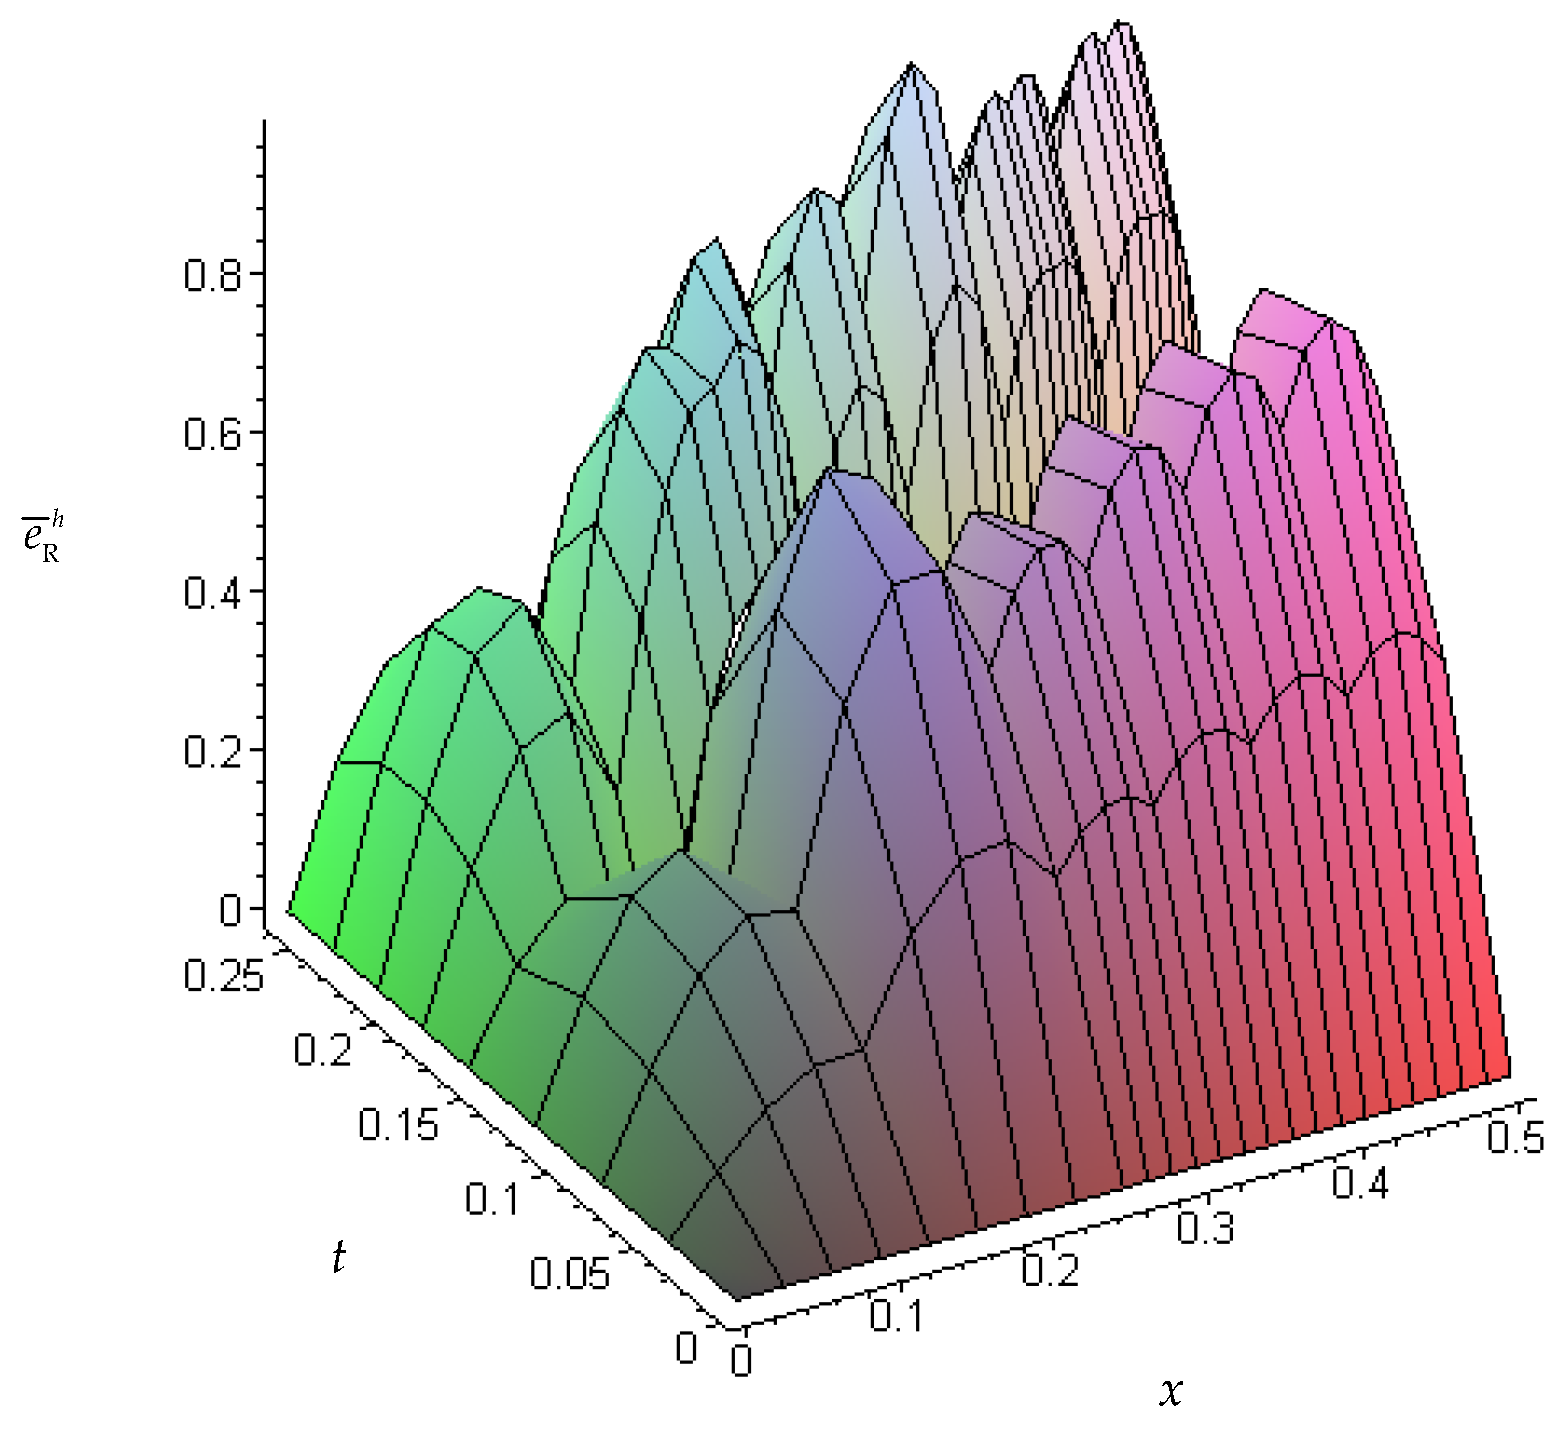
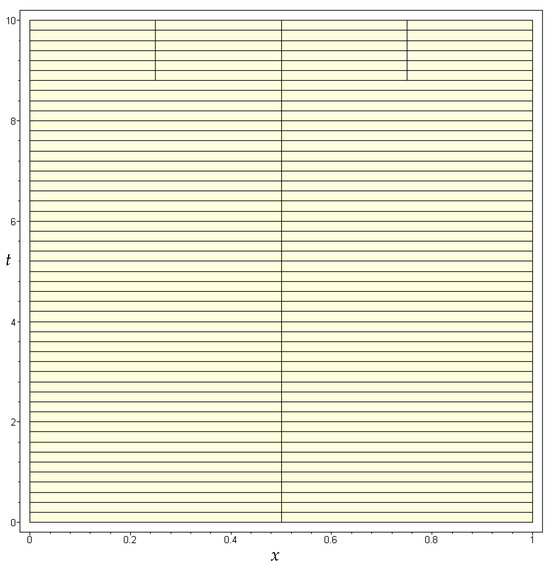
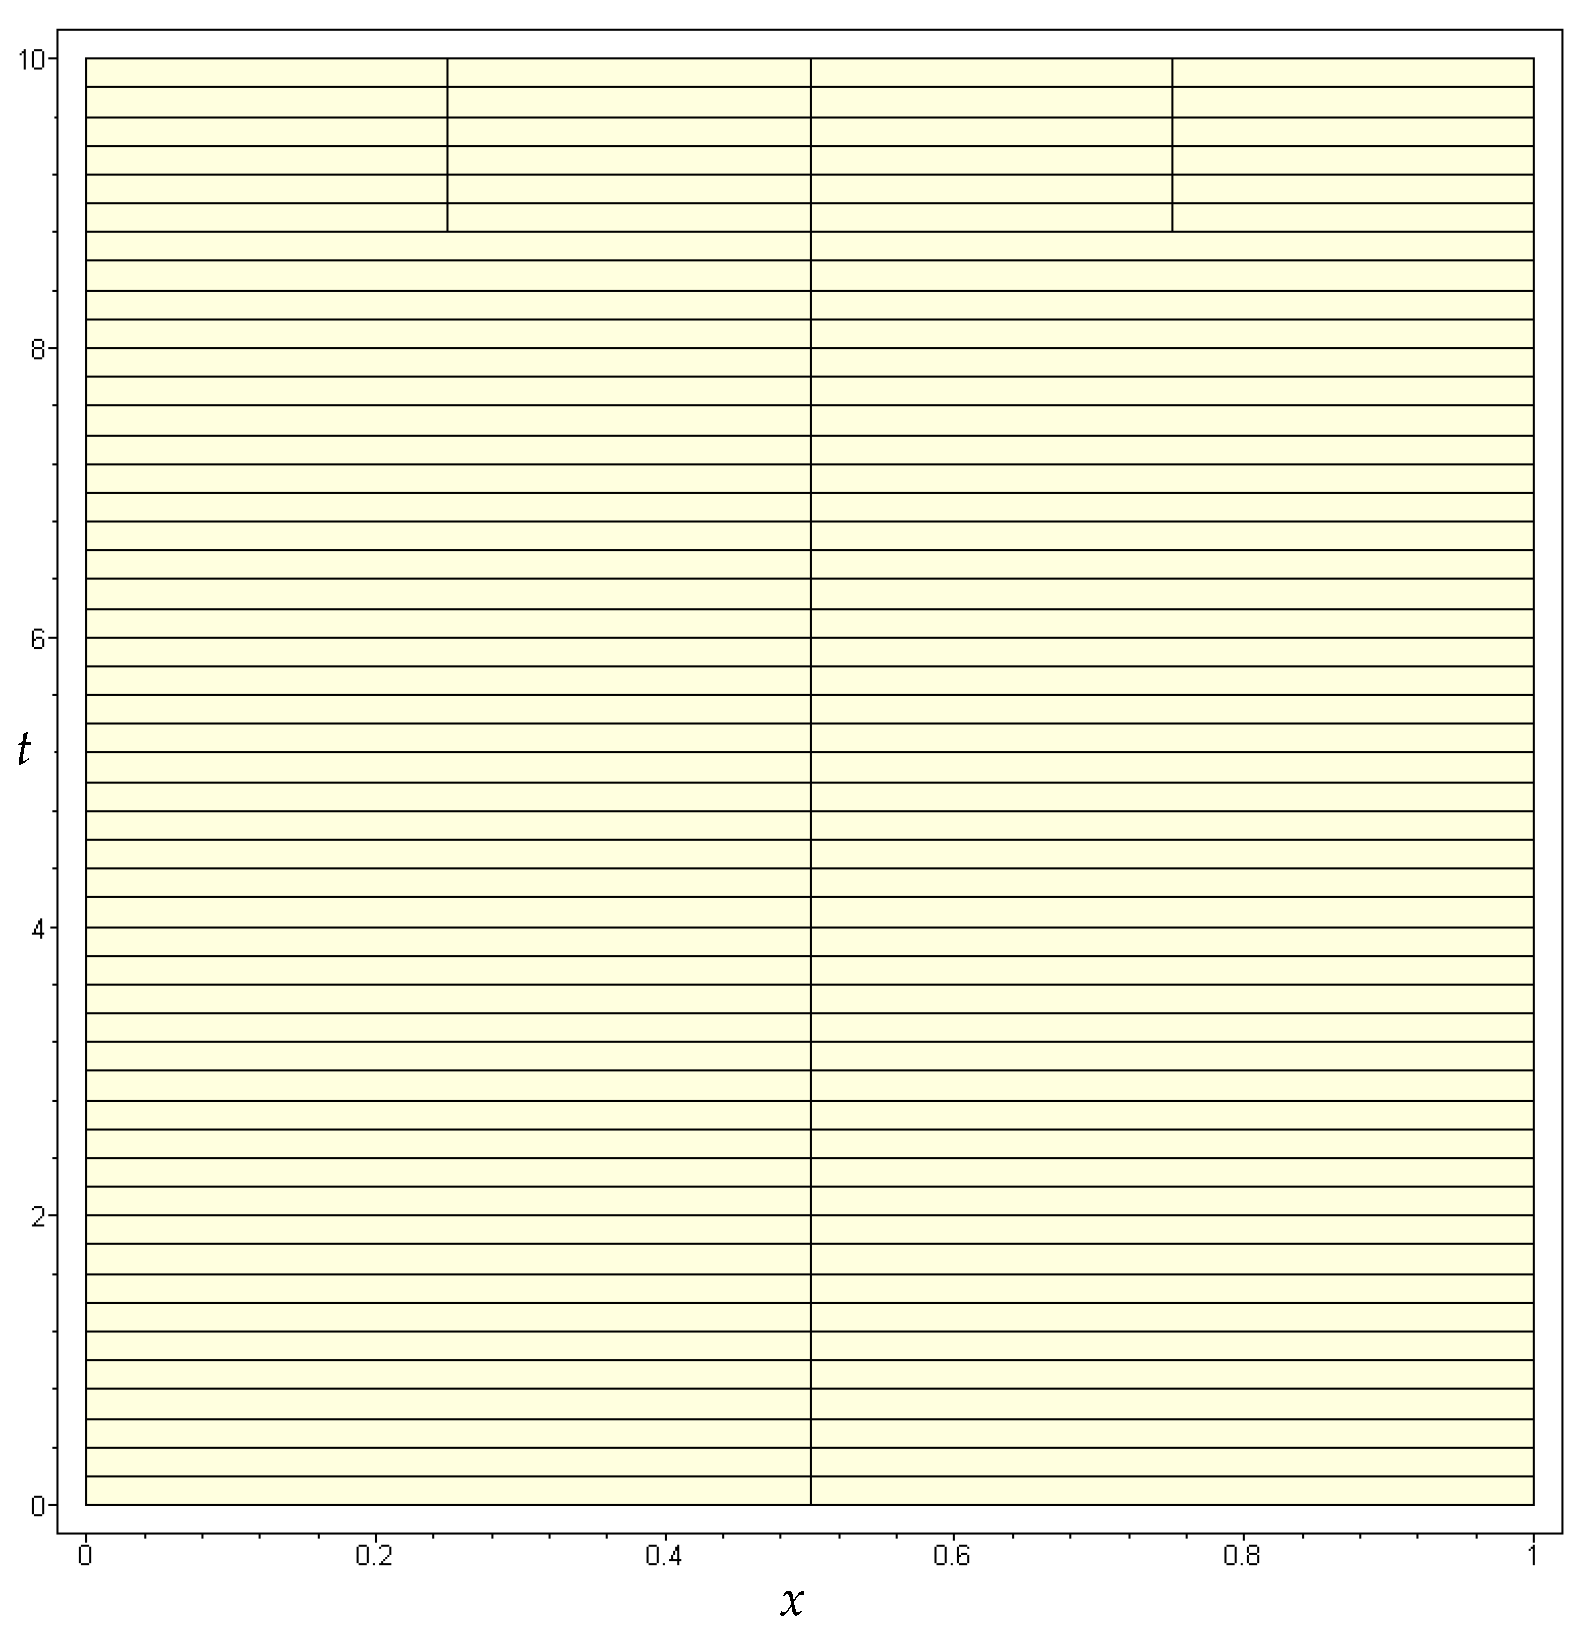
After finishing the first time-step, we proceed to the second time-step with both the spatial mesh and the time-step size inherited from the first time-step, i.e., six space elements and . After adaptative process for the time-step size, it is adjusted to . Then checking each space–time element error shows that the second, fifth and sixth elements exceed the tolerance and need to be bisected, after which a nine-element spatial mesh is generated as shown in Figure 6. This spatial mesh refinement yields some hanging nodes, which present no difficulties and can be easily treated, as done in the interpolation to the initial values by picking up the corresponding solution values of the upper side of the previous time-step. Another round FE run for the nodal line solutions of the current time-step shows that both the time-step size and the spatial mesh are adequate to meet the error tolerance, with the estimated maximum error ratio and true maximum error ratio on the second time-step. It is seen that the estimated error is very close to the true error. The distribution of the true error ratio is shown in Figure 7. Then the adaptive analysis of the second time-step has been successfully fulfilled.
Figure 7.
The true error ratio of the illustrative example.
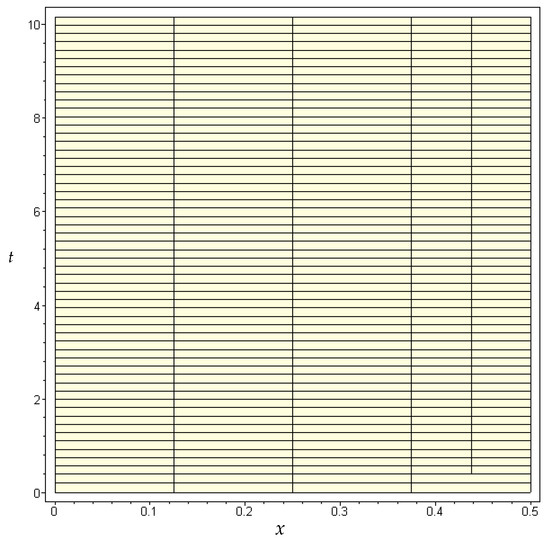
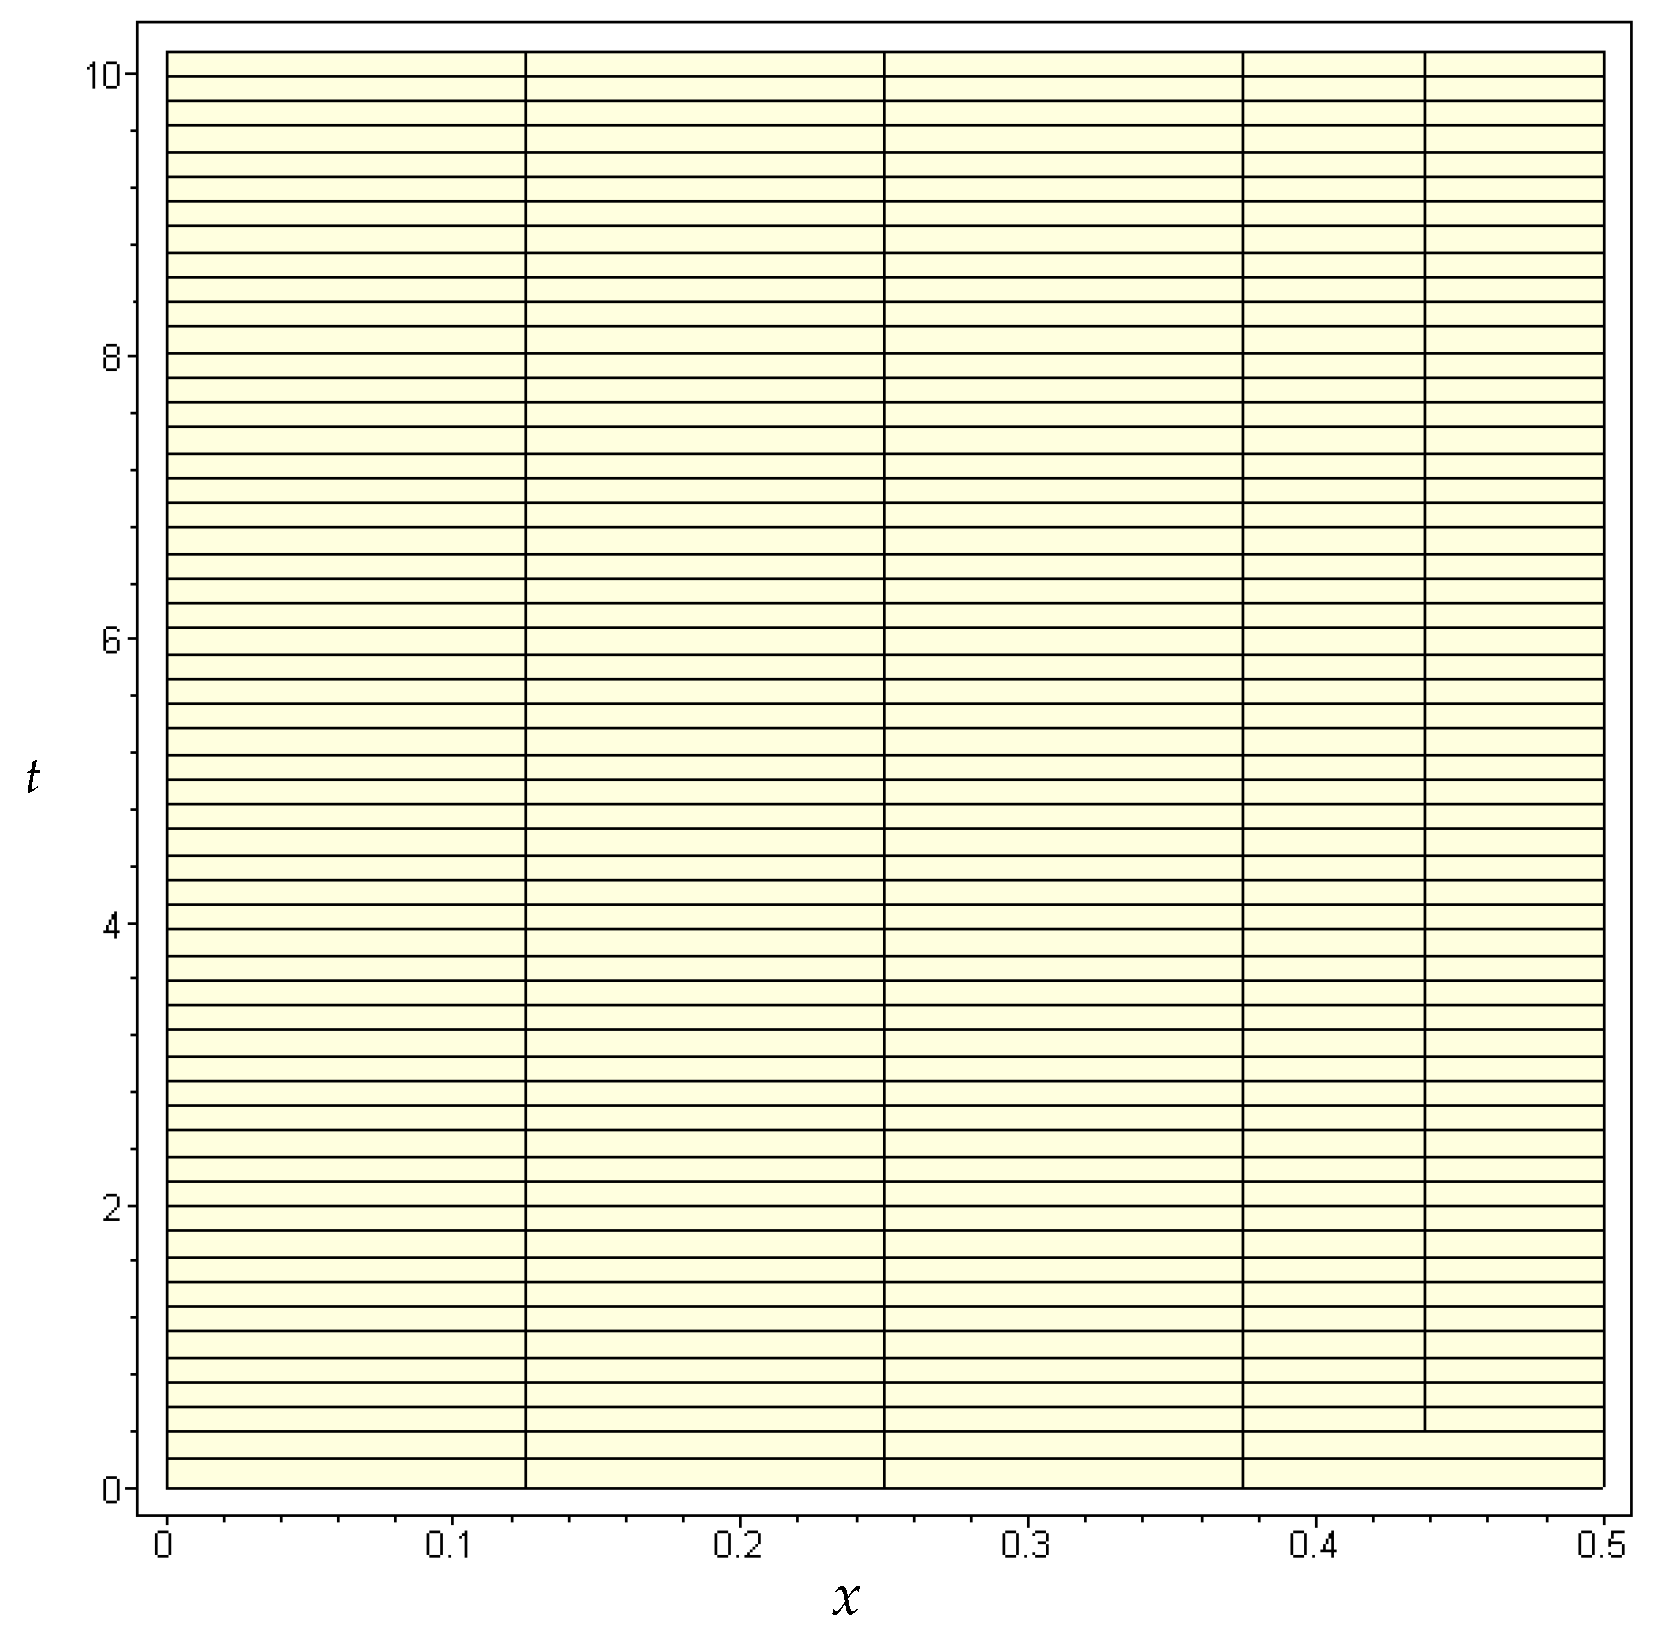
This problem has also been solved on a longer time domain using elements of different degrees with different error tolerances, and the computed results are shown in Table 2. The final mesh for and is shown in Figure 8. It is observed that the most adapted FE solutions strictly satisfy the error tolerances, and the overall performance of the proposed algorithm is satisfactory.
Table 2.
Results of various experiments of illustrative example.
Figure 8.
Final mesh for and .
5.2. An Acoustic Wave Problem
This test problem is Example 5.1 in Ref. [1], which is more challenging. The problem is defined as follows:
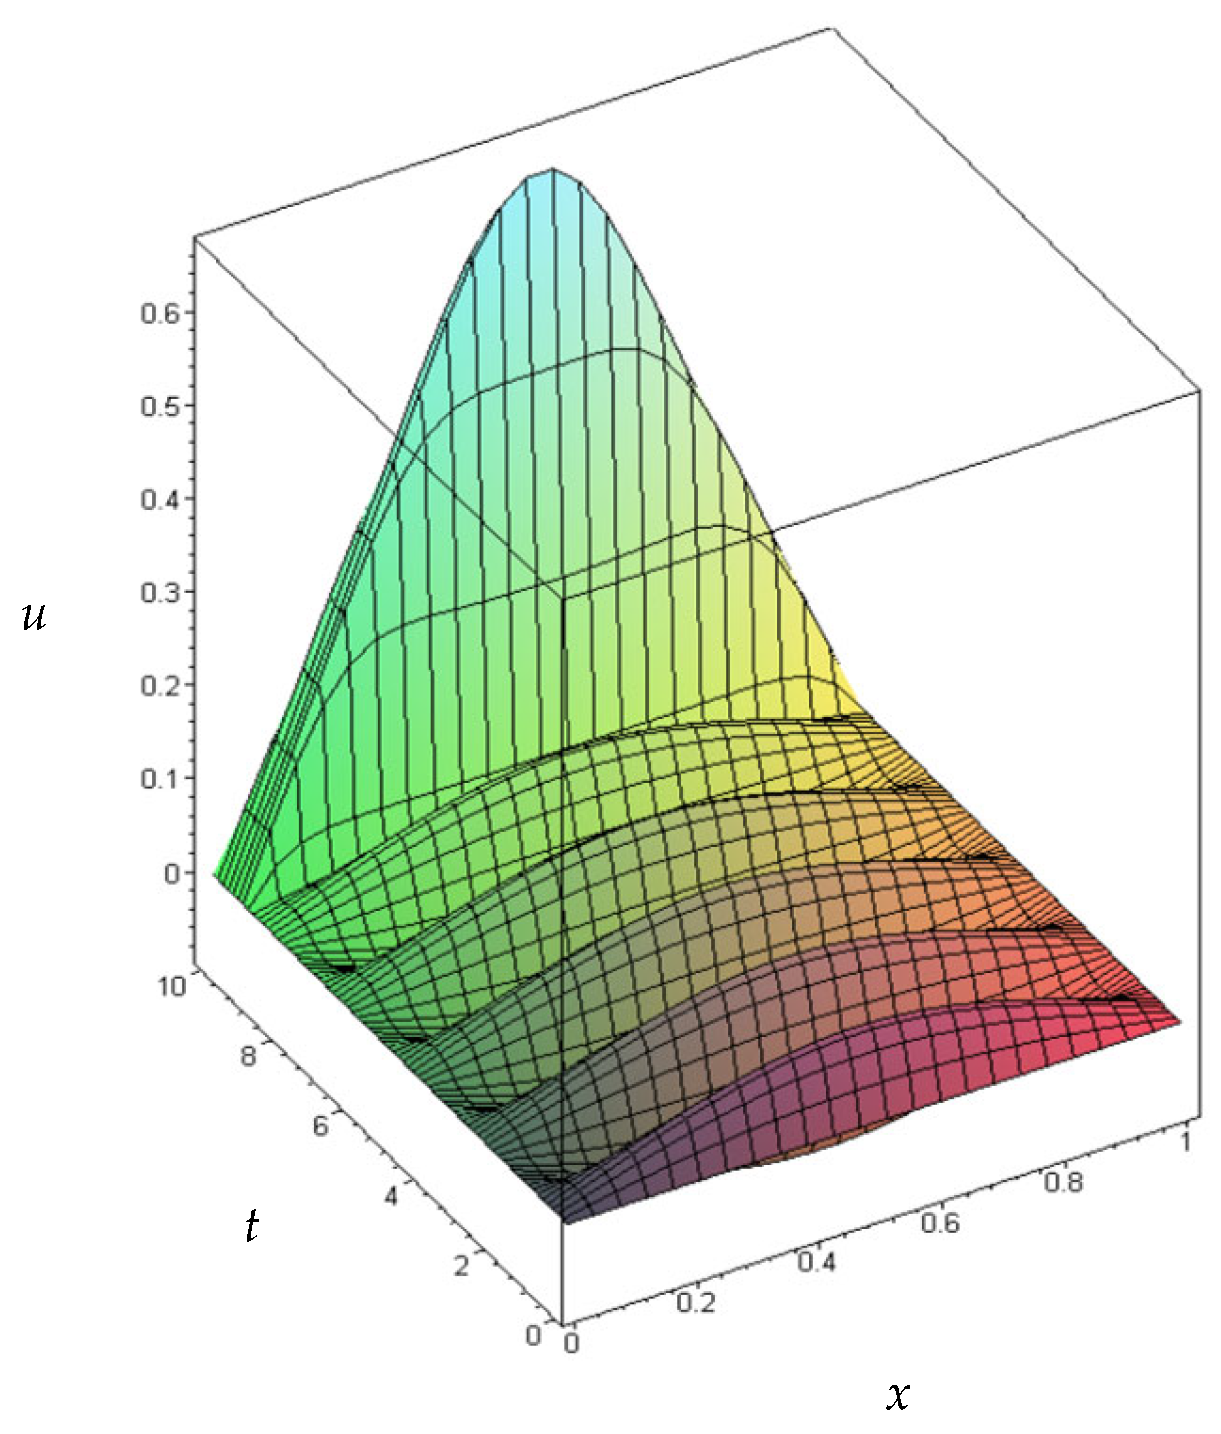
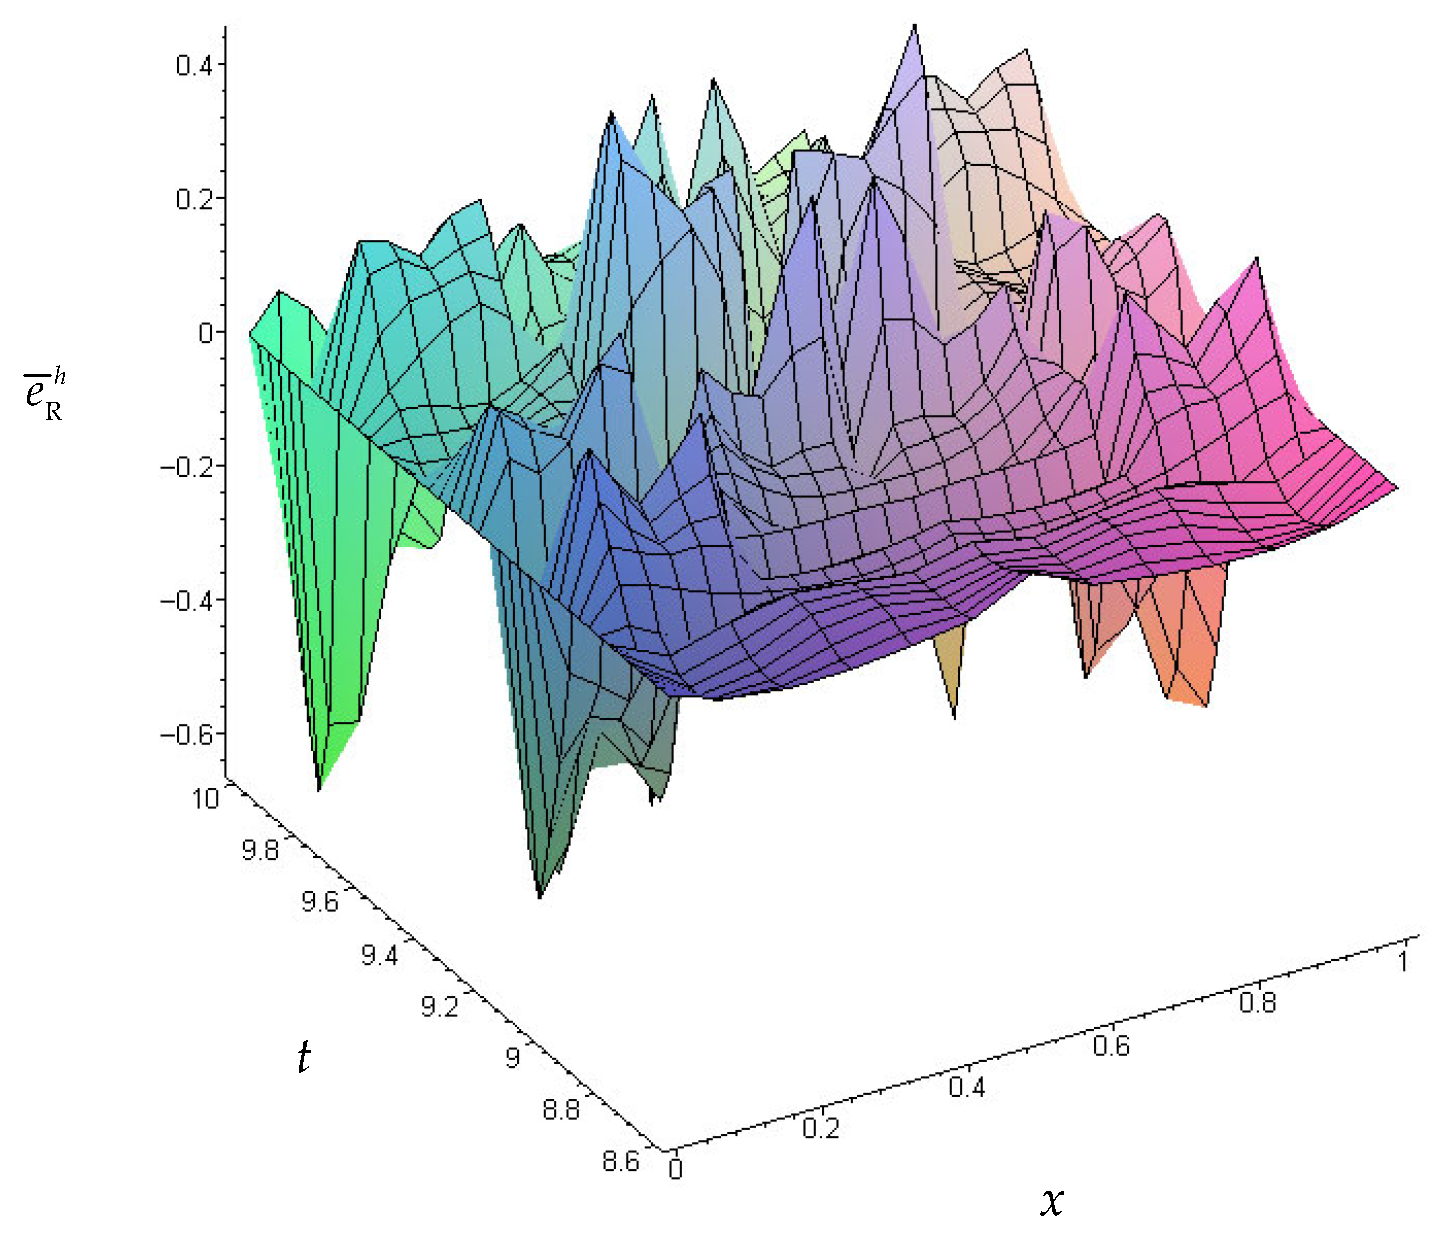
A Fourier series expansion solution of 120 terms is employed to simulate the exact solution for error checking, whose shape is shown in Figure 9. This problem is computed using reduced elements of degree and with error tolerances and , respectively. The computed results are shown in Table 3. For and , the true error ratio distribution and the final mesh are shown in Figure 10 and Figure 11, respectively. It is seen that most FE solutions meet the error tolerances satisfactorily. For and , the true error ratio is not strictly satisfied, for which one of the reasons is that the ‘true’ solution is a series solution, and its accuracy is not sufficient to serve as a true solution for the stringent tolerance .
Figure 9.
Series solution of Example 5.2.
Table 3.
Results of Example 5.2.
Figure 10.
True error ratio of Example 5.2 ().
Figure 11.
Final mesh of Example 5.2 ().
5.3. Constant Initial Velocity Problem
This example considers an elastic string with fixed ends excited by an initial velocity , which is defined as follows:
The string is fixed at two ends where the velocity is equal to zero, i.e., , hence the initial velocity is discontinuous in space at the two ends.
5.3.1. Ten-Term Series Solution as the Objective
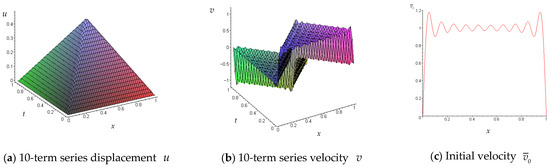
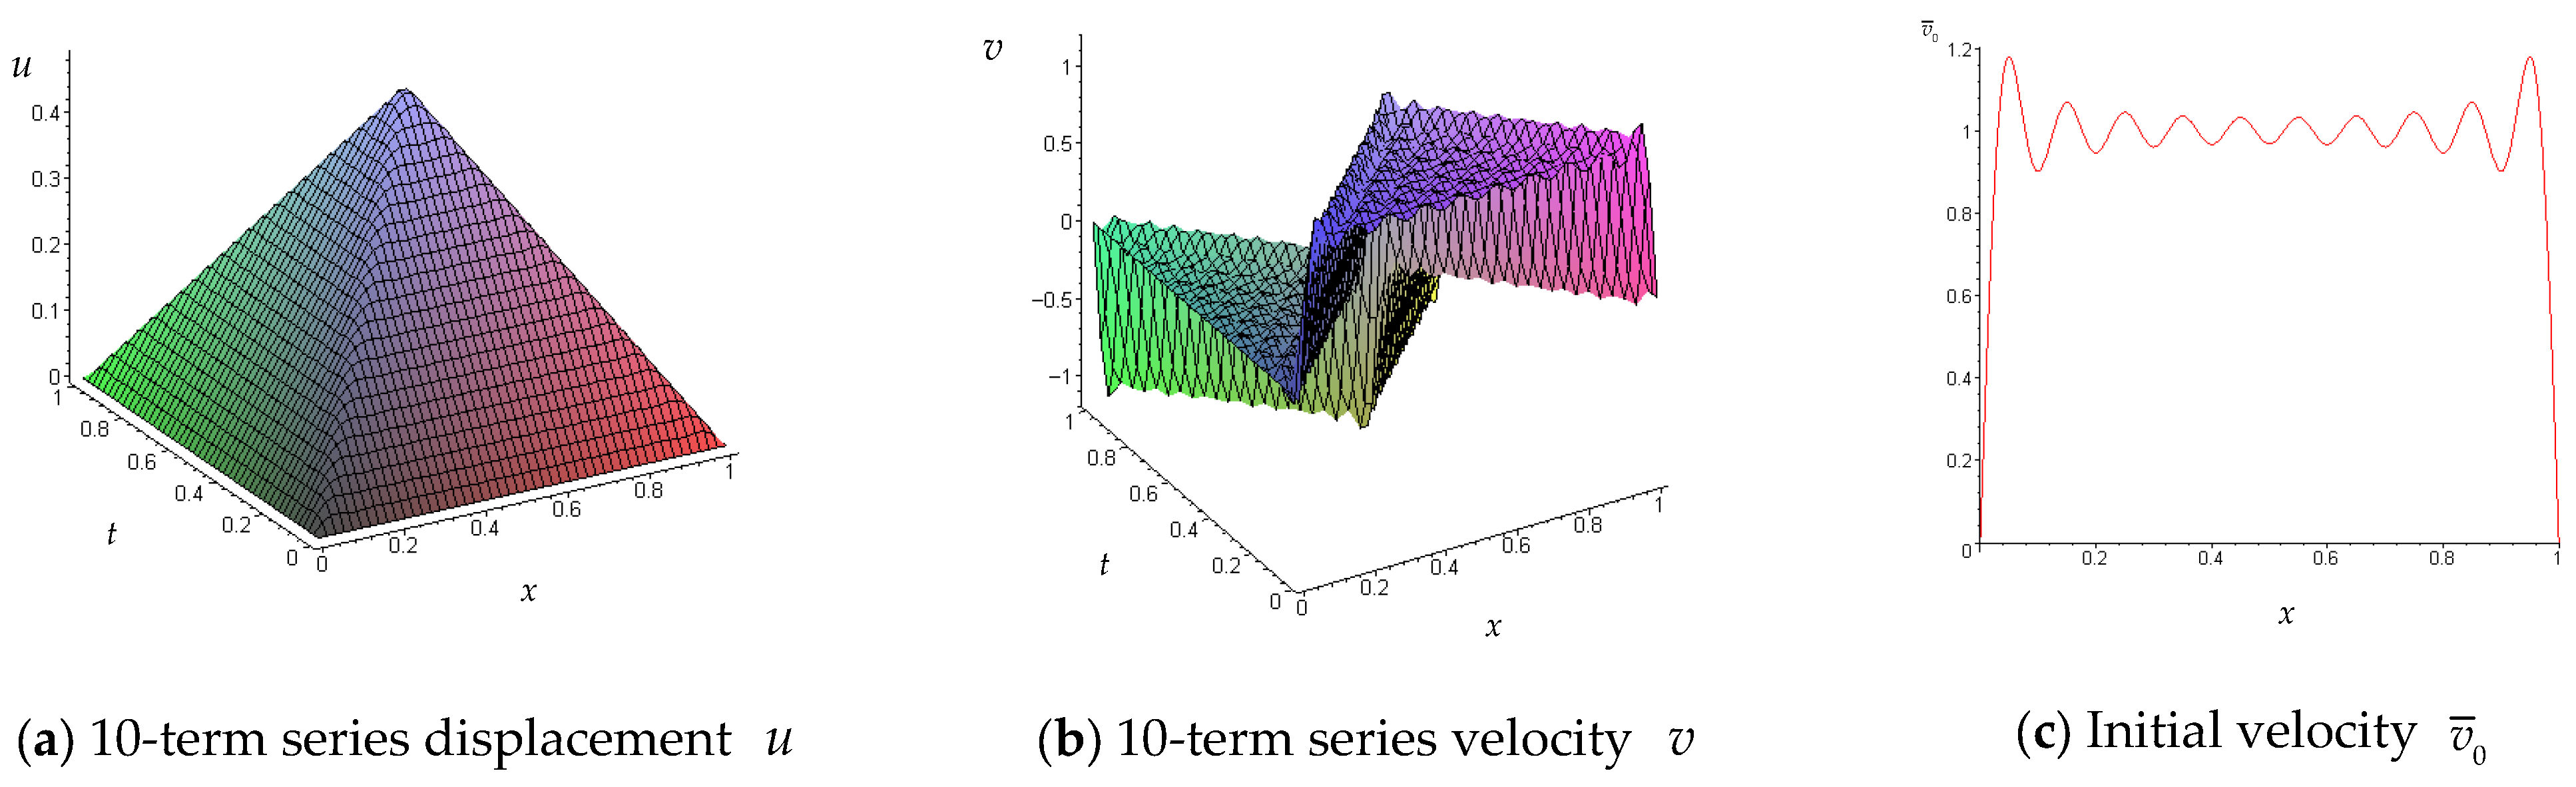
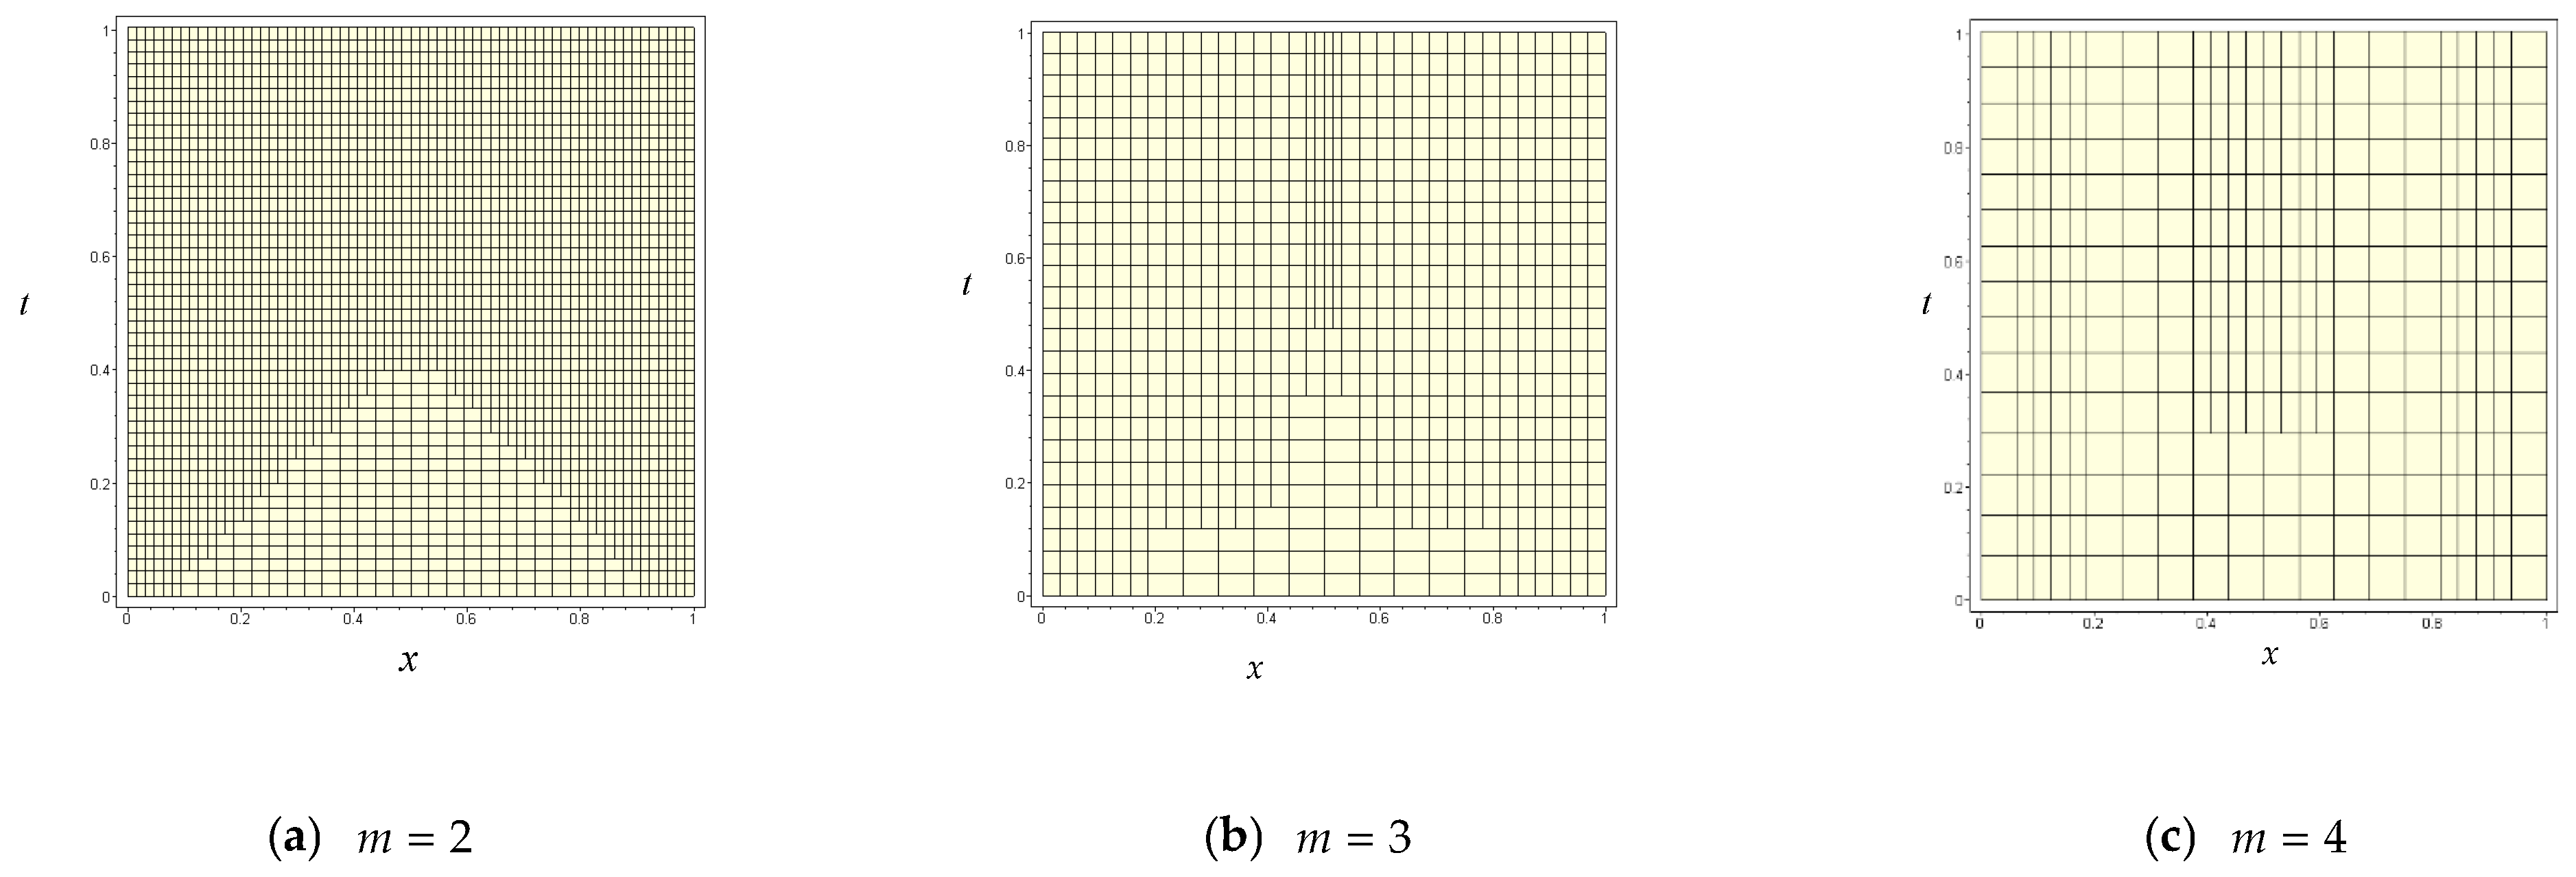
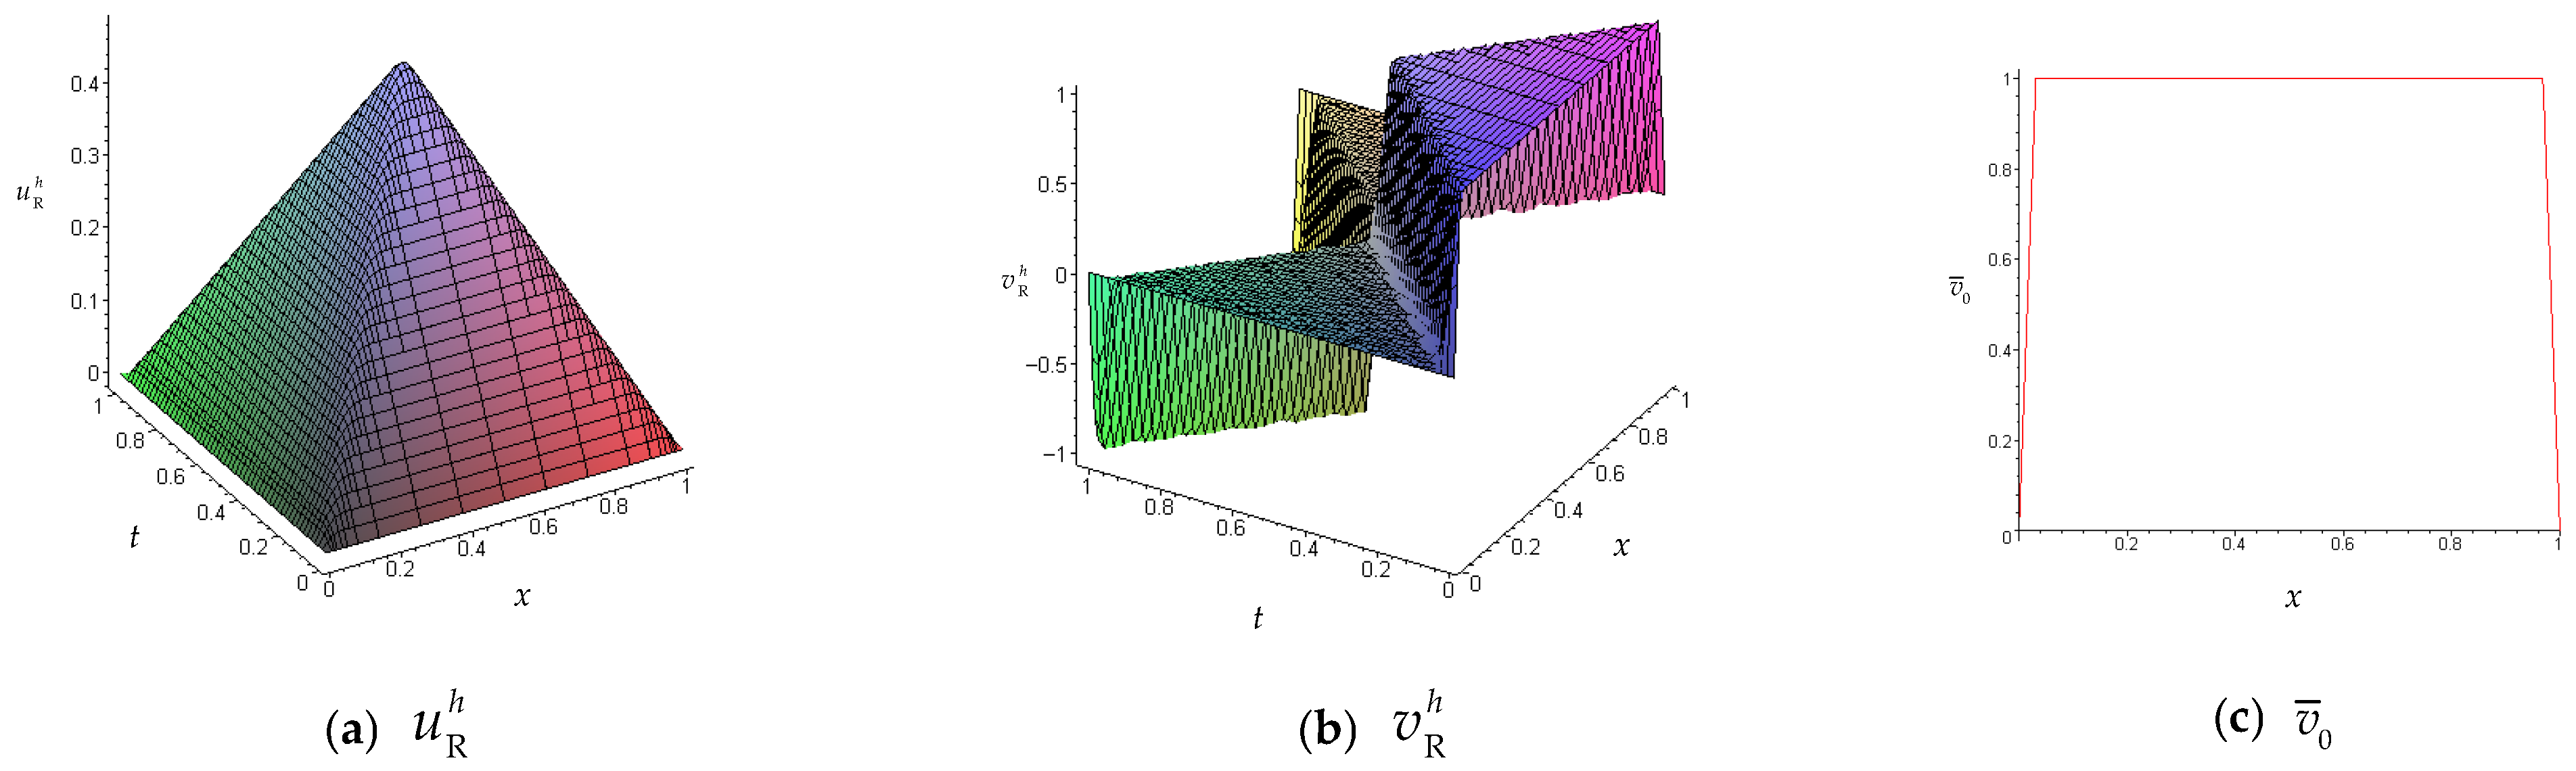
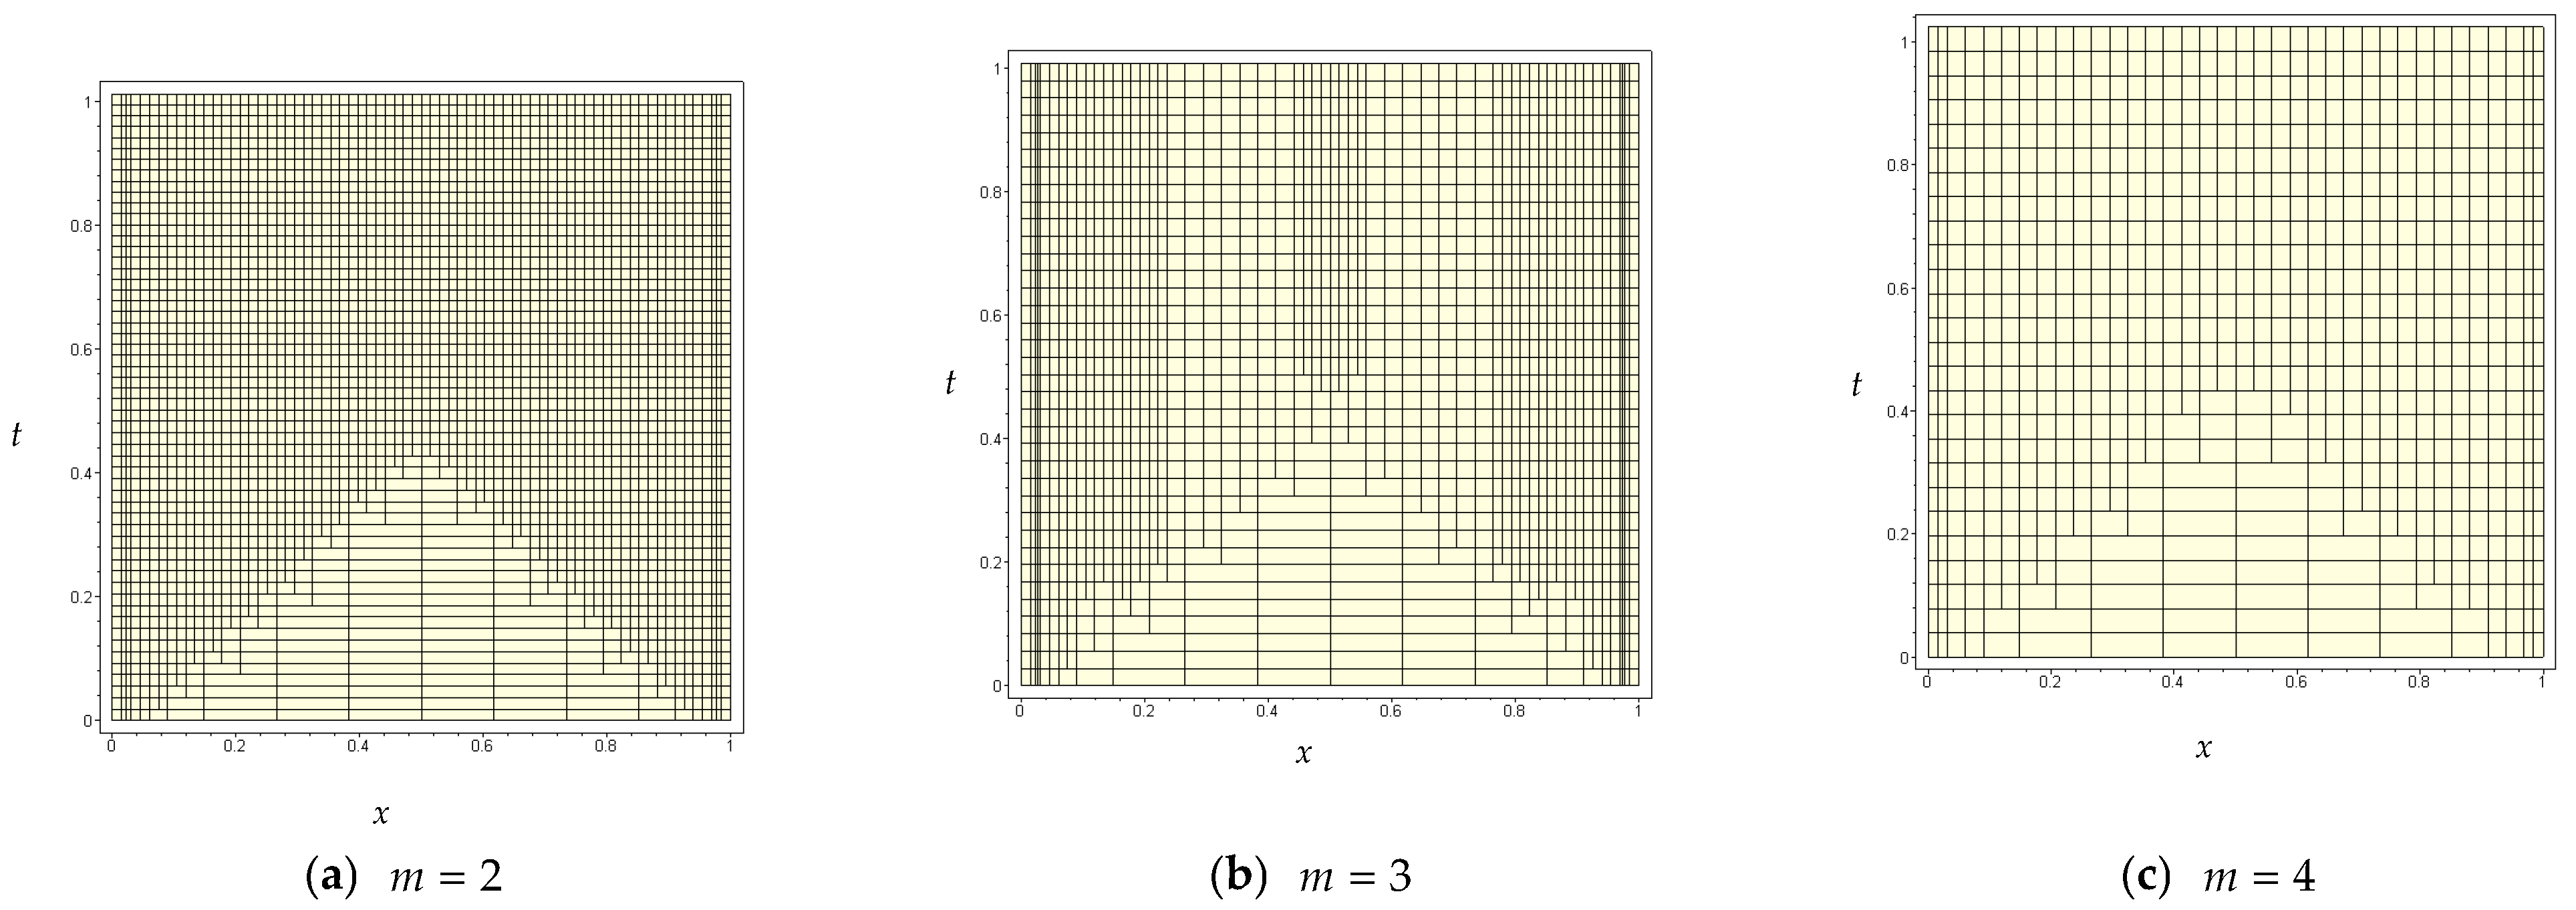
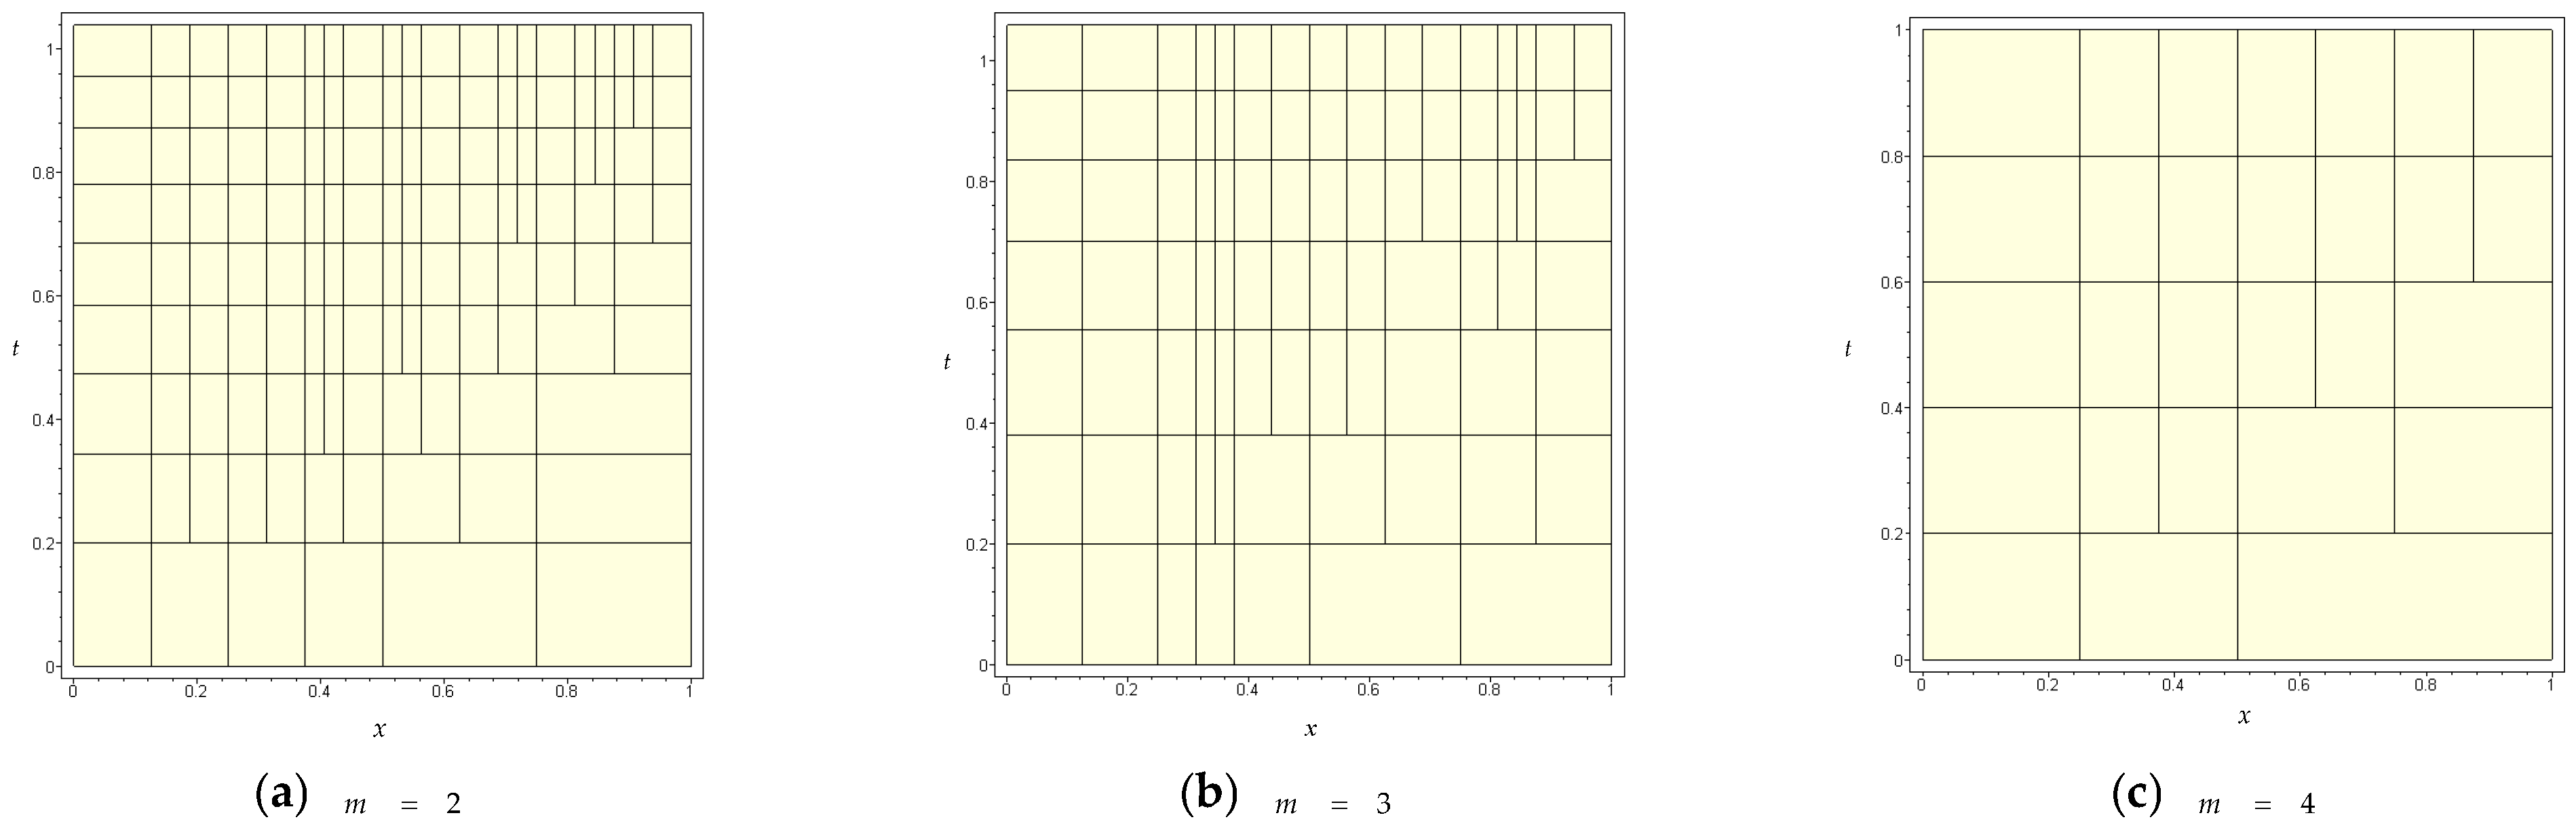
In this case, the 10-term series solution is taken as the exact solution as shown in Figure 12a,b and the derived initial velocity is shown in Figure 12c. This treatment removes the discontinuity of the initial velocity, but the steep variations at the two ends would demand corresponding adaptivity efforts. Table 4 gives the computed results of different element degrees and tolerances. For , Figure 13 shows the final meshes for elements of different degrees. It is seen that most FE solutions meet the error tolerances satisfactorily.
Figure 12.
Displacement , velocity , and initial velocity from a 10-term series solution.
Table 4.
Problem of constant initial velocity (series solution as the objective).
Figure 13.
Final meshes of the adaptive analysis with reduced elements of different degrees.
5.3.2. Piecewise Linear Approximation to Constant Velocity
In this case, instead of the series solution, the exact solution is the adaptive objective. However, to remove the discontinuity of the initial velocity, the initial velocity is modeled by a piecewise linear approximation as follows:
as shown in Figure 14c. Since the exact solution is not available, the true errors cannot be evaluated either. For , reduced elements of different degrees are taken in computation. Figure 14a,b shows the reduced solutions of . Figure 15 shows the final meshes for the elements of different degrees. It is seen that the reduced solution and are smoother than those in Example 5.3.1 and is trusted to be closer to the exact solution.
Figure 14.
Displacement , velocity , and initial velocity from reduced elements of degree 2.
Figure 15.
Final meshes of the adaptive analysis with reduced elements of different degrees of Example 5.3.2.
5.4. Moving Concentrated Load
This example considers an elastic string with fixed ends subjected to a concentrated load moving from the left end to the right end at a velocity , which is defined using the Dirac function as follows:
For simplicity, we set , for which the exact solution can readily be obtained using the Heaviside function as follows:
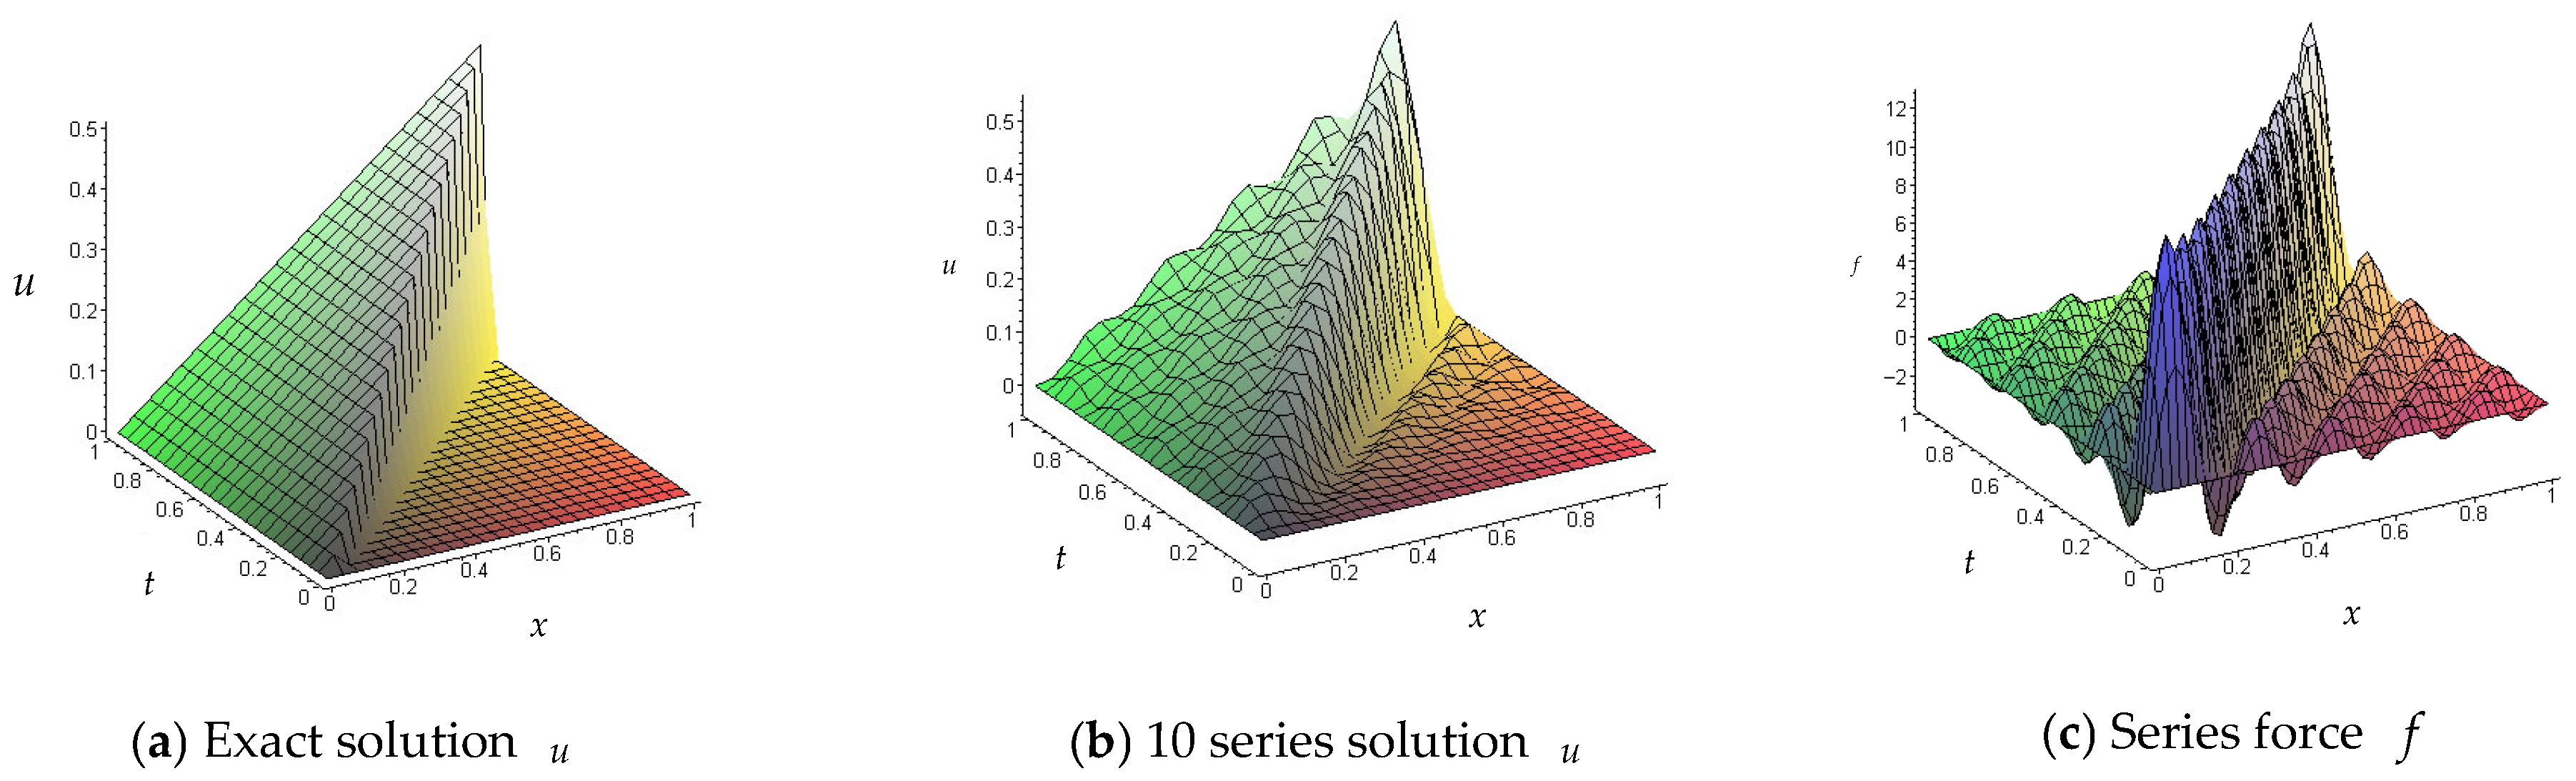
which is shown in Figure 16a. In this case, the displacement on the two sides of is discontinuous and the corresponding velocity is singular.
Figure 16.
Exact solution , series solution of ten terms and its derived load term.
5.4.1. Ten-Term Series Solution as the Objective
In this case, the 10-term series solution is taken as the exact solution as shown in Figure 14b and the load term is derived from the specified solution as shown in Figure 14c. Table 5 gives the computed results of different element degrees and tolerances. For , Figure 17 shows the final meshes for elements of different degrees. It is seen that most FE solutions meet the error tolerances satisfactorily.
Table 5.
Problem of moving load (series solution as the objective).
Figure 17.
Final meshes of the adaptive analysis with reduced elements of different degrees of Example 5.4.1.
5.4.2. Direct Concentrated Load
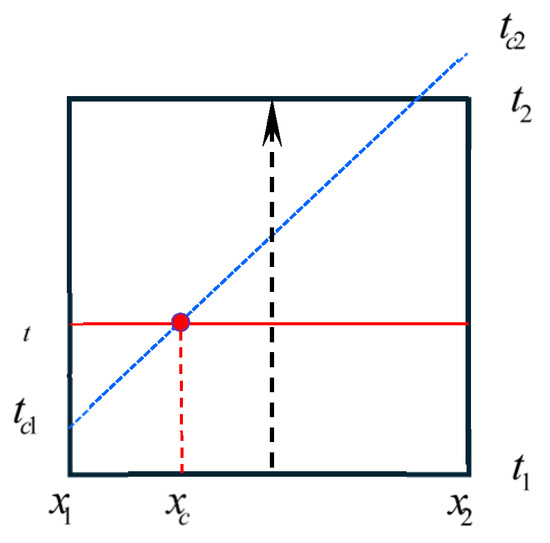
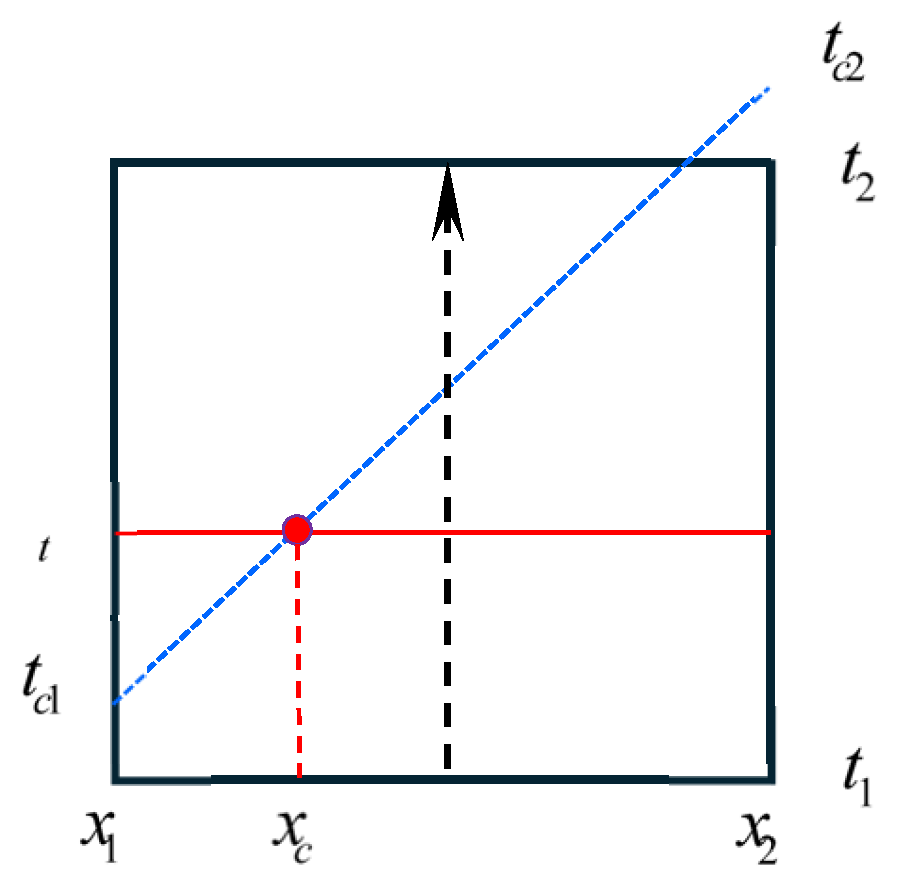
In this case, instead of the series solution, the exact solution is the adaptive objective with the concentrated load directly applied at the appropriate position. Figure 18 shows an illustrative example of the moving load passing a typical element. Suppose the load is at for the time . For the particular time , the equivalent nodal line load vector in Equation (10) can be calculated using spatial coordinate as
Figure 18.
Example of moving load on an element.
To transform the above formula into a function of time , note that , and . Then when , there is no load on the time interval , and when , there is no load on either. Therefore, to keep the lower and upper bounds and unchanged for the current time-step, can be calculated as follows:
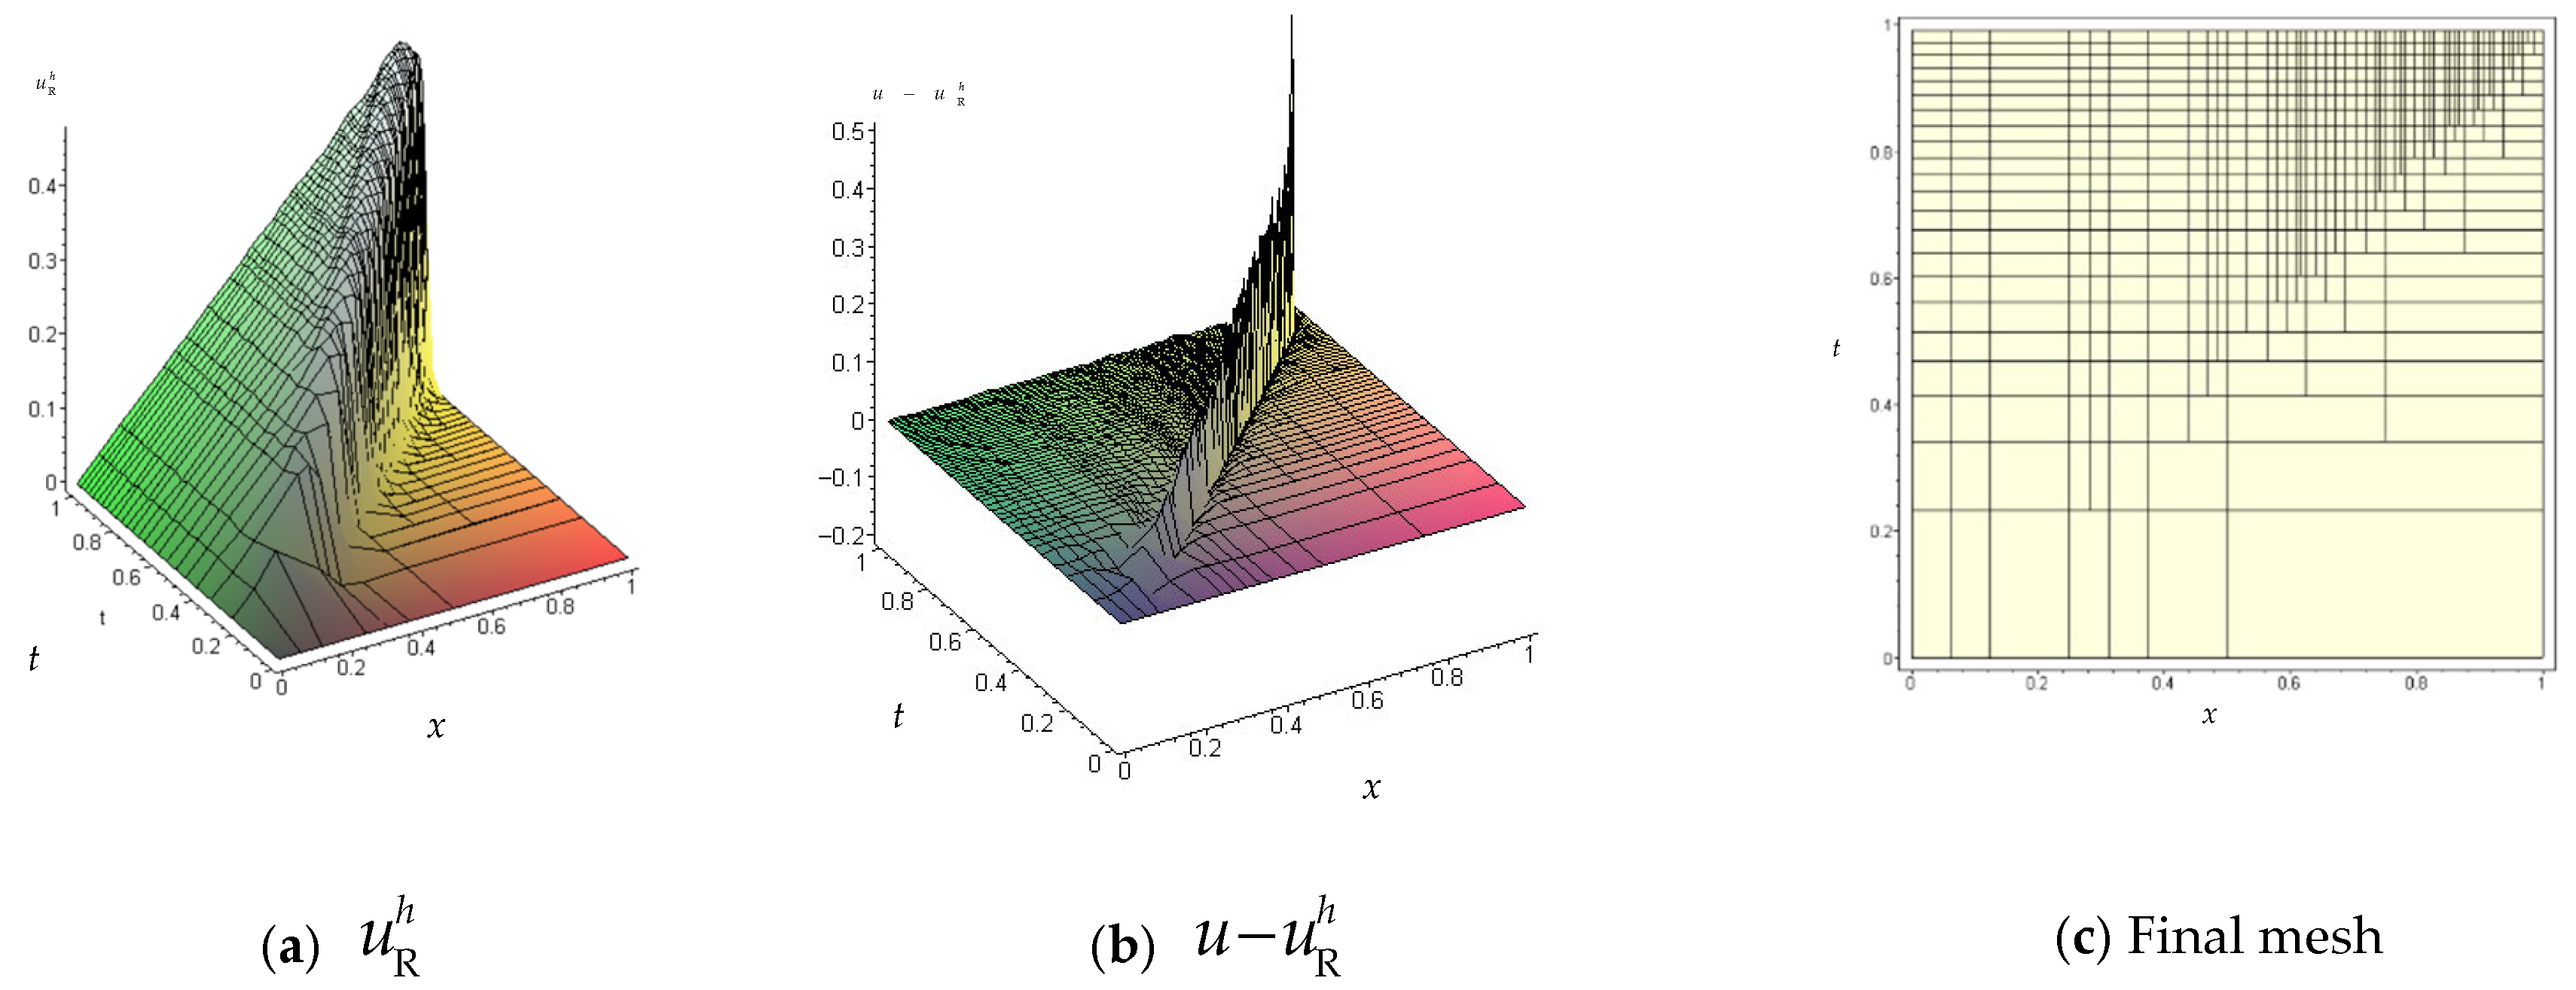
For , reduced elements of different degrees are taken in computation. Figure 19 shows the reduced solutions of and final mesh. It is seen that the adapted mesh is reasonably refined and the reduced solution and are smoother on plane surfaces than those in Example 5.4.1 with the large errors mainly located along the discontinuous diagonal line.
Figure 19.
Displacement , error , and final mesh of reduced elements of degree 2.
5.5. Vibration with Damping and an Elastic Foundation
This example considers an elastic string with fixed ends subjected to a sudden uniform load with damping and an elastic foundation , which is defined as follows:
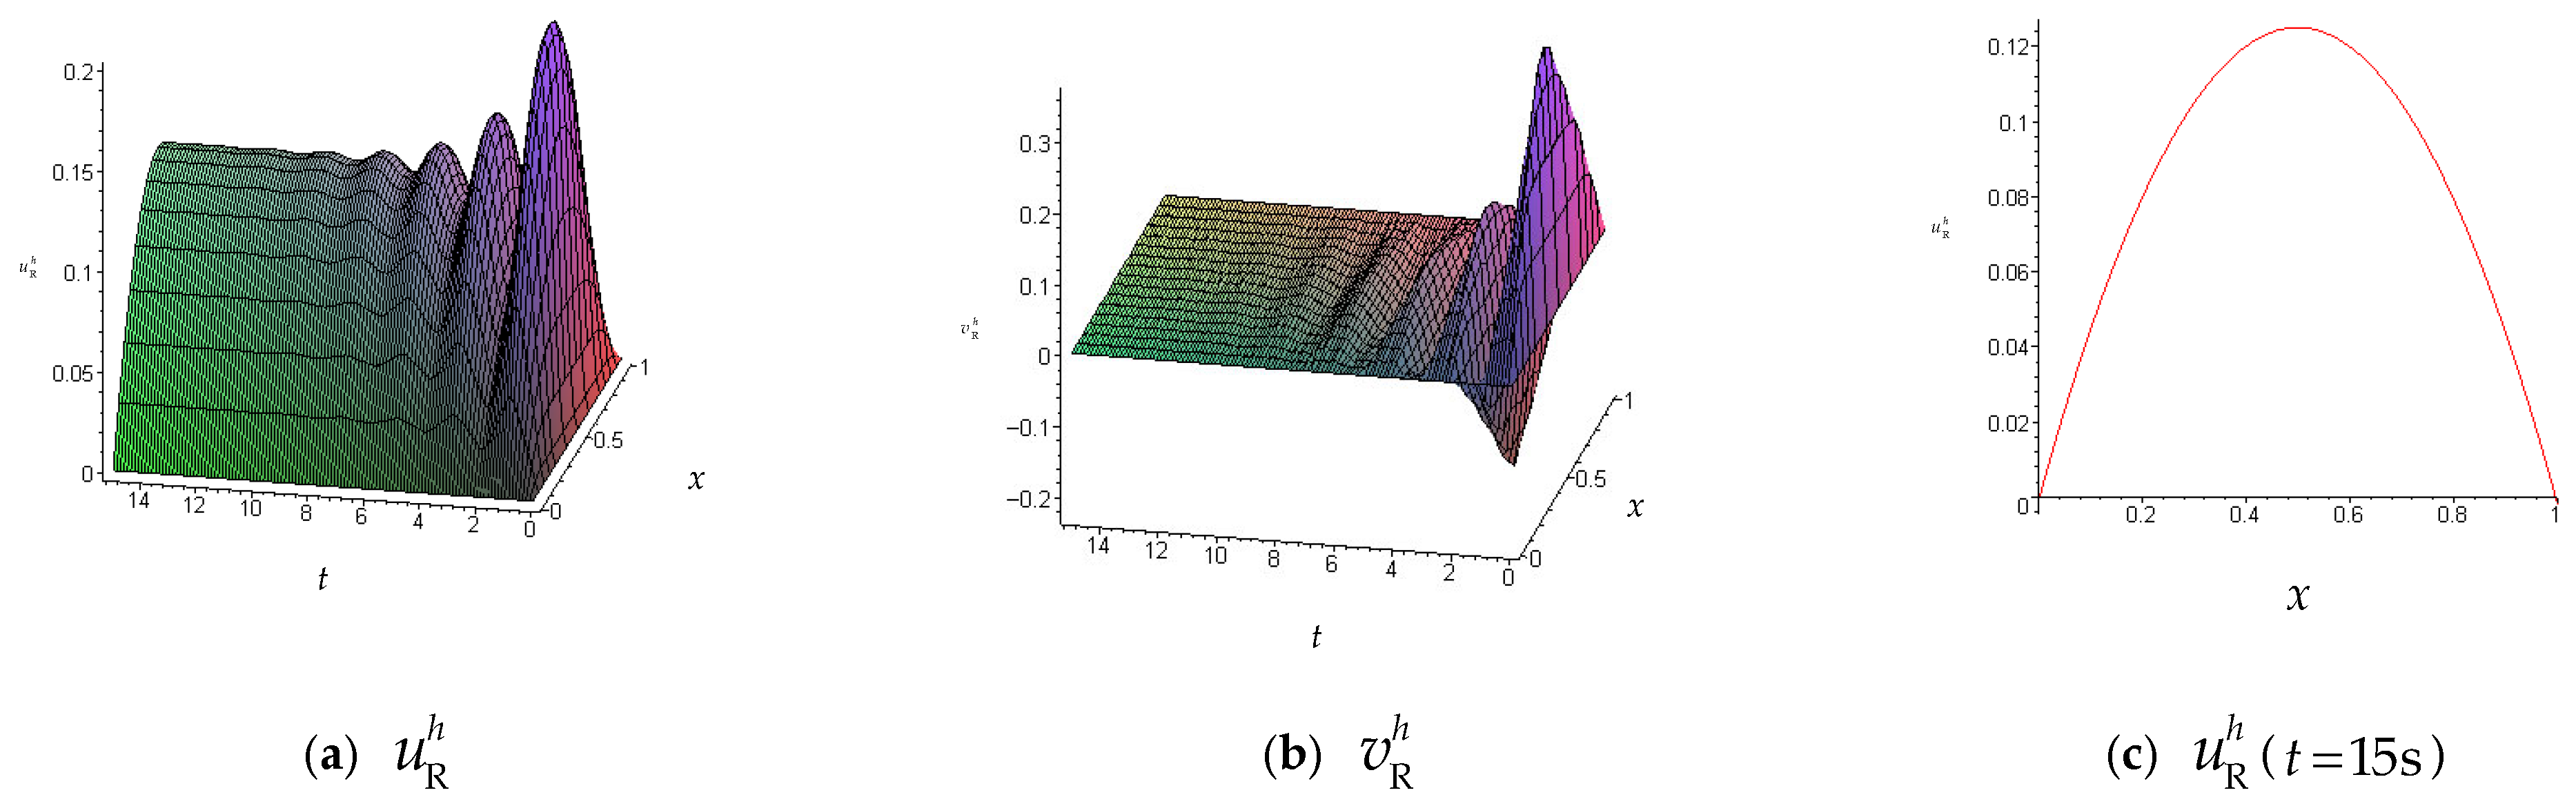
The quadratic reduced element () is used with . Since there is no exact solution available, a long time domain of is deliberately chosen so that a steady state can be achieved at the terminal time, which can be compared with the computed result.
5.5.1. Vibration with Damping Alone
In this case, and are taken in computation. Figure 20 shows the adapted reduced solutions of displacement, velocity on the space–time domain and the displacement at the end time. As a check, the computed displacement at the mid-span at the terminal time is 0.125029, which is very close to the exact steady state value .
Figure 20.
Displacement , velocity and steady state () from reduced elements of .
5.5.2. Vibration with Both Damping and an Elastic Foundation
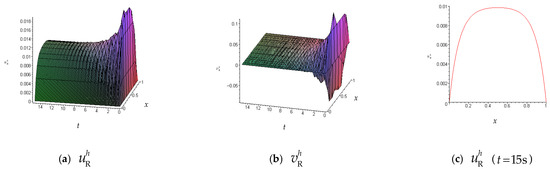
In this case, and are taken in computation. Figure 21 shows the adapted reduced solutions of displacement, velocity on the space–time domain and the displacement at the terminal time. As a check, the computed displacement at the mid-span at the terminal time is 0.009870, which is very close to the exact steady-state value 0.009865.
Figure 21.
Displacement , velocity and steady state () from reduced elements of .
6. Conclusions
A new type of the Galerkin space–time finite element, referred to as the space–time reduced element, is introduced by interweaving the advantages of the reduced elements for both IVPs and BVPs. The conventional FE solutions are decomposed into two parts: a reduced element solution, which serves as the final solution, and an error term, which is used as a built-in pointwise error estimator. Using the elastic string vibration equation as a model problem, a complete adaptivity algorithm is developed. Through mathematical analysis and numerical experiments, it is shown that for a wide range of problems, including forced vibrations with damping on an elastic foundation and moving load problems, FE solutions derived from the reduced element can be obtained that satisfactorily satisfy user-preset error tolerances in the maximum norm.
Author Contributions
Q.Y.: Writing—Original draft, Software, Validation, Conceptualization, Formal analysis, Investigation, Data curation, Methodology. S.Y.: Writing—Review and editing, Supervision, Project administration, Conceptualization, Resources, Methodology, Funding acquisition. All authors have read and agreed to the published version of the manuscript.
Funding
This work was supported by the National Natural Science Foundation of China (No. 51878383). The authors are solely responsible for the content.
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
The original contributions presented in the study are included in the article, further inquiries can be directed to the corresponding author.
Conflicts of Interest
The authors declare that they have no conflicts of interest.
References
- Bangerth, W.; Geiger, M.; Rannacher, R. Adaptive Galerkin finite element methods for the wave equation. Comput. Methods Appl. Math. 2010, 10, 3–48. [Google Scholar] [CrossRef] [Scilit]
- Bangerth, W.; Rannacher, R. Adaptive finite element techniques for the acoustic wave equation. J. Comput. Acoust. 2001, 9, 575–591. [Google Scholar] [CrossRef] [Scilit]
- Dumbser, M.; Käser, M.; Toro, E.F. An arbitrary high-order discontinuous Galerkin method for elastic waves on unstructured meshes V.: Local time stepping and p-adaptivity. Geophys. J. Int. 2007, 171, 695–717. [Google Scholar] [CrossRef] [Scilit]
- Li, X.D.; Wiberg, N.E. Implementation and adaptivity of a space-time finite element method for structural dynamics. Comput. Methods Appl. Mech. Eng. 1998, 156, 211–229. [Google Scholar] [CrossRef] [Scilit]
- Idesman, A.V. Application of space-time finite elements to elastodynamics problems. In 8th International Conference on Numerical Methods in Industrial Forming Processes; Springer: Cham, Switzerland, 2024; pp. 2282–2287. [Google Scholar]
- Hughes, T.J.; Hulbert, G.M. Space-time finite element methods for elastodynamics: Formulations and error estimates. Comput Methods Appl. Mech. Eng. 1988, 66, 339–363. [Google Scholar] [CrossRef] [Scilit]
- Hulbert, G.M. Time finite element methods for structural dynamics. Int. J. Numer. Methods Eng. 1992, 33, 307–331. [Google Scholar] [CrossRef] [Scilit]
- Thompson, L.L.; He, D.T. Adaptive space-time finite element methods for the wave equation on unbounded domains. Comput. Methods Appl. Mech. Eng. 2005, 194, 1947–2000. [Google Scholar] [CrossRef] [Scilit]
- Steinbach, O. Space-time finite element methods for parabolic problems. Comput. Methods Appl. Math. 2015, 15, 551–566. [Google Scholar] [CrossRef] [Scilit]
- Gorynina, O.; Lozinski, A.; Picasso, M. Time and space adaptivity of the wave equation discretized in time by a second-order scheme. IMA J. Numer. Anal. 2019, 39, 1672–1705. [Google Scholar] [CrossRef] [Scilit]
- Loscher, R.; Steinbach, O. Space-time finite element methods for distributed optimal control of the wave equation. Siam J. Numer. Anal. 2024, 62, 452–475. [Google Scholar] [CrossRef] [Scilit]
- Sharma, V.; Shimizu, S.; Fujisawa, K. Space-time finite element method with domain reduction techniques for dynamic soil-structure interaction problems. Int. J. Mech. Syst. Dyn. 2024, 4, 117–130. [Google Scholar] [CrossRef] [Scilit]
- French, D.A.; Peterson, T.E. A Continuous Space-Time Finite Element Method for the Wave Equation. Math. Comput. 1996, 65, 491–506. [Google Scholar] [CrossRef] [Scilit]
- Idesman, A.V. A new high-order accurate continuous Galerkin method for linear elastodynamics problems. Comput. Mech. 2007, 40, 261–279. [Google Scholar] [CrossRef] [Scilit]
- Bause, M.; Radu, F.A.; Koecher, U. Error analysis for discretizations of parabolic problems using continuous finite elements in time and mixed finite elements in space. Numer. Math. 2017, 137, 773–818. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Yuan, Q.; Yuan, S. Reduced element for adaptive finite element analysis of first-order IVP with built-in error estimator in maximum norm. Appl. Sci. 2024, 14, 7264. [Google Scholar] [CrossRef] [Scilit]
- Yuan, S.; Yang, S.; Yuan, Q.; Wang, Y. New progress in reduced element: An adaptive finite element method with built-in error estimator in maximum norm. Eng. Mech. 2024, 41, 1–8. (In Chinese) [Google Scholar]
- Yuan, S. The Finite Element Method of Lines: Theory and Applications; Science Press: Beijing, China; New York, NY, USA, 1993. [Google Scholar]
- Yuan, Q.; Yuan, S. Condensed Galerkin Time-Element for Structural Dynamics with Adaptive Time-Stepping in Maximum Norm. Int. J. Comput. Methods 2024, 21, 2450034. [Google Scholar] [CrossRef] [Scilit]
- Xing, X.; Zhang, X.; Lu, M. A time integration method based on the weak form Galerkin method. Eng. Mech. 2006, 23, 8–12. (In Chinese) [Google Scholar]
- Hulme, B.L. One-step piecewise polynomial Galerkin methods for initial value problems. Math. Comput. 1972, 26, 415–426. [Google Scholar] [CrossRef]
- Strang, G.; Fix, G. An Analysis of the Finite Element Method, 2nd ed.; Wellesley-Cambridge Press: Wellesley, MA, USA, 2008. [Google Scholar]
- Zienkiewicz, O.C.; Zhu, J.Z. The superconvergent patch recovery and a posteriori error estimates. Part 2: Error estimates and adaptivity. Int. J. Numer. Methods Eng. 1992, 33, 1365–1382. [Google Scholar] [CrossRef] [Scilit]
- Szabó, B.; Babuška, I. Introduction to Finite Element Analysis: Formulation, Verification and Validation; John Wiley & Sons: Chichester, UK, 2011. [Google Scholar]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.