Article

Experimental and Computational Study of Rotational Lift Production of Insect Flapping Wing

by
May Hlaing Win Khin
1,2,*,
Samuel Verboomen
2 and
Shinnosuke Obi
2,*
1
Department of Mechanical Engineering, West Yangon Technological University, Yangon 114002, Myanmar
2
Department of Mechanical Engineering, Keio University, Yokohama 223-8522, Japan
*
Authors to whom correspondence should be addressed.
Appl. Sci. 2026, 16(2), 724; https://doi.org/10.3390/app16020724
Submission received: 5 December 2025 / Revised: 30 December 2025 / Accepted: 6 January 2026 / Published: 9 January 2026

Abstract

This paper investigates the rotational lift production of translating and rotating wings within a small insect’s Reynolds number range. Using the Reynolds number 1200 of a bumblebee, three wing section profiles were studied: a circular cylinder model as a reference for a blunt body for which the well-known Magnus effect will occur, a flat plate model as a reference for a sharp body for which the Kramer effect will occur, and finally, an elliptical cylinder model as a transition case. Direct force measurement and particle image velocimetry (PIV) experiments were performed to measure the lift produced and the surrounding flow velocity, and the Kutta–Joukowski theorem was applied to analyze the PIV results. The Kutta–Joukowski theorem gives the relationship between lift and circulation on a body moving at constant speed in a real fluid with some constant density. The experimental results were analyzed and verified by comparing them to the computational results. In general, there is reasonable agreement between the experimental and computational results, confirming that the Magnus effect is observed for the circular cylinder model and no Kramer effect is observed for the flat plate model. The elliptical cylinder model does not appear to be blunt enough for the Magnus effect to occur, and it is not sharp enough for the Kramer effect to occur.

1. Introduction

Unmanned Air Vehicles (UAVs) and Biomimetic Air Vehicles (BAVs) are used as low-cost and efficient solutions in various fields for security, surveillance, and remote control. Therefore, research on the aerodynamics of insect flapping flight has gained attention in recent years. Insect wings ranging from 1 to 100 mm in wingspan typically produce two to three times more lift than can be accounted for by conventional aerodynamics [1]. Flapping wings also improve, at small scales, both maneuverability and energy efficiency, supporting the ability to hover.
The differences between actual planes and insects’ flight mainly rely on the Reynolds number. For actual planes, which have higher Reynolds numbers, theory supports fairly accurate analysis. However, as the Reynolds number decreases, the viscous effect is no longer negligible. As such, for insects or small birds, for which the Reynolds number is between 101 and 104, the aerodynamic principles are fundamentally different. Within this range of Reynolds numbers, several studies have been conducted to investigate the impact of this parameter on the force produced. For example, Daniel K Hope, Anthony M DeLuca, and Ryan P O’Hara investigated the behavior of a Manduca sexta-inspired biomimetic wing as a function of the Reynolds number. They measured the aerodynamic forces produced by varying the characteristic wing length and testing at air densities from atmospheric to near vacuum [2].
Studying the unsteady nature of insect flight and the complex flow surrounding their flapping wings may improve our knowledge and our capacity to innovate real-world applications.
When insects and small birds hover with their small wings, the Reynolds number should be too small to support their weight in a quasi-steady state. However, due to quasi-steady translational lift and unsteady lift-enhancement mechanisms, it does. Four of these mechanisms will be briefly explained [3].
The first one is a delayed stall of the leading-edge vortex (LEV) [4,5]. When the wing accelerates, a starting vortex is created to satisfy the Kutta–Joukowski condition. As a response, a bound vortex appears and increases the circulation around the wing and lift production [5]. While the wing accelerates, this vortex can be maintained for a few chord lengths. It then becomes unsteady.
The second mechanism is wake capture, which refers to the interaction between the wing and the wake. When a wing meets the wake created during the previous stroke after reversing its direction, the effective flow speed surrounding the airfoil increases, generating a second force peak. Even if the wing suddenly stops after just the rotation, lift production still occurs due to the previous wake [6].
The third mechanism is added mass acceleration. Added mass is the inertia added to a system because an accelerating or decelerating body must move some volume of surrounding fluid as it moves through it. Added mass is intuitive, as the body and the fluid cannot occupy the same physical space at the same time. For simplicity, this can be modeled as some volume of fluid moving with the object, although in reality, all of the fluid accelerates to varying degrees. It is difficult to distinguish the added mass effect from wake capture when the flow is fully developed [7]. When this added inertia goes in the lift direction, it can increase the total lift. When bodies are very sharp or the surrounding fluid has a low density, it can be neglected. However, in our case, we generally cannot omit it.
The fourth mechanism is rapid-pitch up or rotational lift, the effect of the rotation of the wings when they fold back [8]. Between the downstroke and the upstroke (and reverse), the wing quickly supinates (pronates) to keep the same leading edge. This fast rotation induces a rotational lift. A wing can achieve a lift coefficient above the steady stall value when the wing rotates from a low to high angle of attack. Hence, flow separation before an AoA (angle of attack) of 45° can be observed (compared to ≈15° in steady motion) [3]. This effect of rotational lift is the focus of the present study.
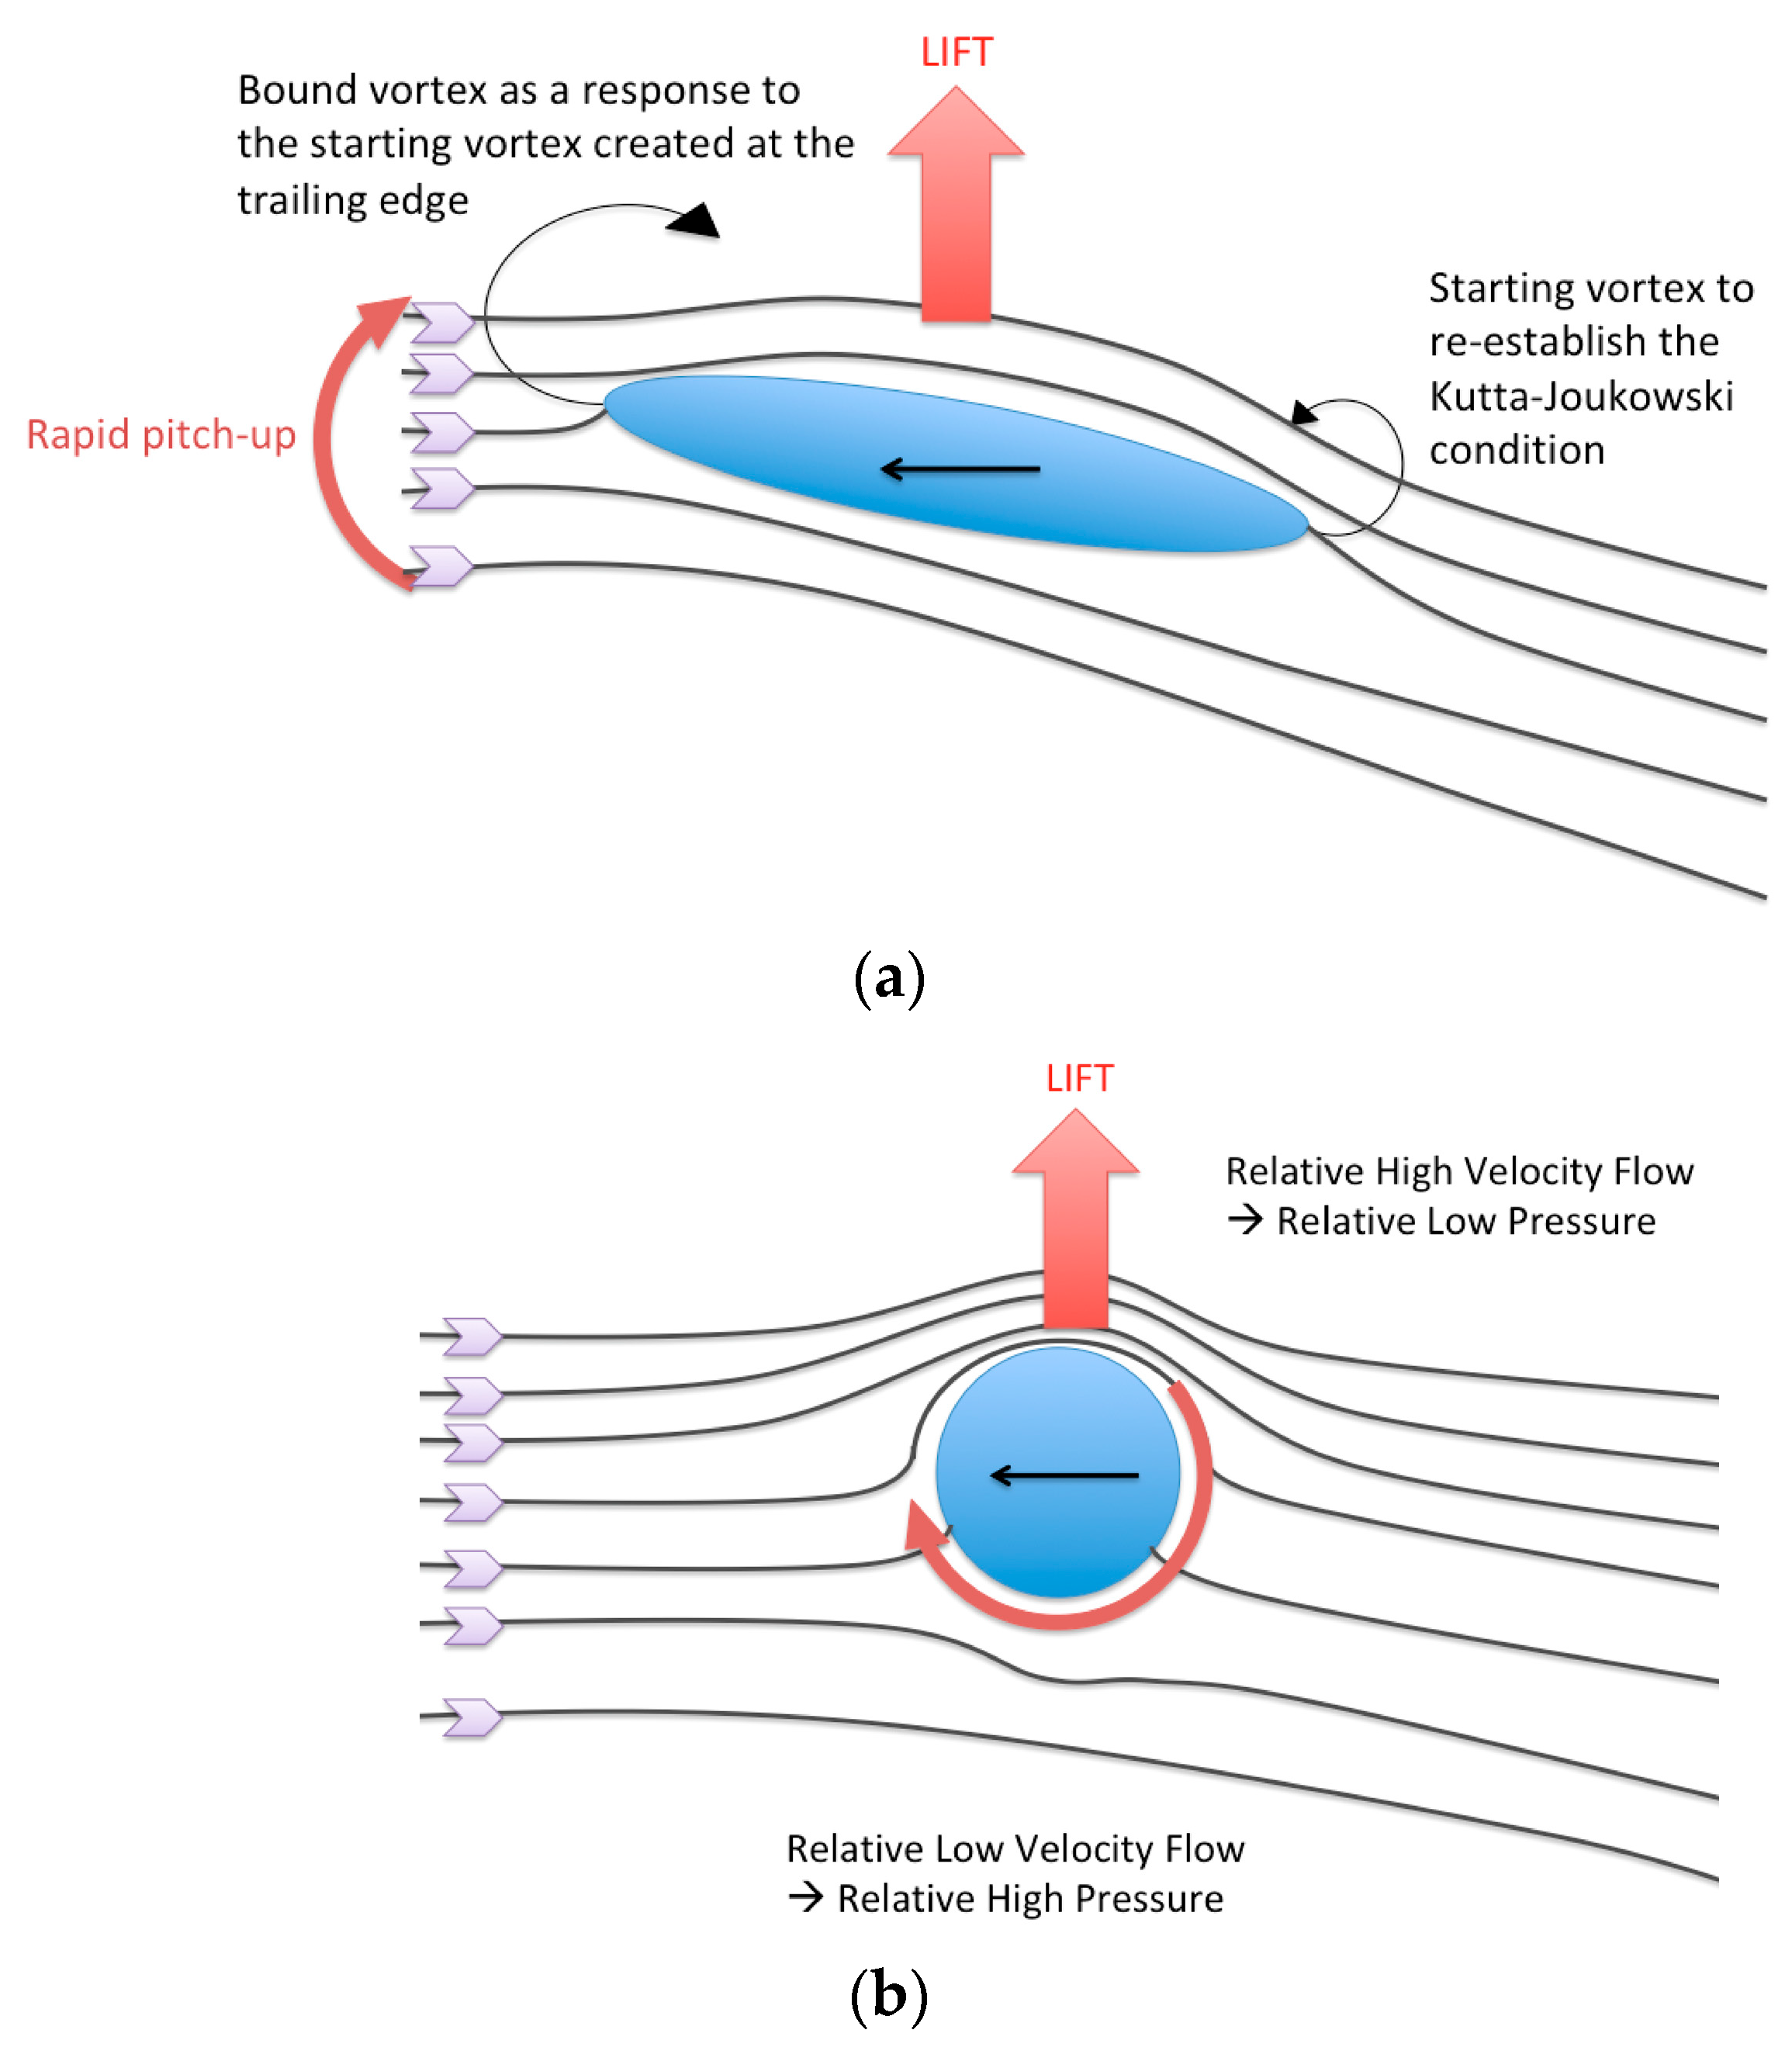
Dickinson et al. [9] explained the aerodynamics of insect flight through the interaction of three distinct mechanisms: delayed stall, rotational circulation, and wake capture. While delayed stall is a translational mechanism, rotational circulation depends explicitly on the pronation and supination of the wing during stroke reversal. This rotational circulation can enhance the generation of the rotational force, which is termed the Kramer effect. The Kramer effect, as shown in Figure 1a, occurs on bodies with a sharp trailing edge [10]. When bodies, mainly wings, rotate quickly, the Kutta–Joukowski condition is no longer satisfied. To re-establish this condition, a starting rotational vortex appears. As a response, a bound vortex is created to counter this starting vortex. Hence, an increase in rotational circulation and lift generation is observed.
In recent years, there has been much interest in the rotational lift production of insect flight. Sane et al. [8] attributed the rotational circulation generated to preserve the Kutta condition at the trailing edge during the wing’s rotation to force peak generation. The flow visualization of tethered fruit flies conducted by Dickinson et al. [11] predicted that maximum flight forces would be generated during the downstroke and ventral reversal, suggesting considerable force generation during wing rotation. Considerable force generation during wing rotation was observed in the computational analysis conducted by Sun and Tang [12]. They found that considerable lift could be produced when the majority of wing rotation is conducted near the end of the stroke or when wing rotation precedes stroke reversal. Insects can achieve precise flight control by modulating the relative timing of wing rotation and stroke reversal [13]. Dickinson et al. [9] suggested that an advance in rotation relative to translation results in a positive lift peak, whereas a delay in rotation results in negative lift.
As mentioned, the rotational lift generated during the pronation and supination at the end of each flapping stroke impacts total lift production. However, its unsteady nature leads to a lack of understanding of this effect. Although many studies have been conducted to better understand the origin of this effect and the surrounding flow structure created during rotation, it remains unclear.
Dickinson et al. [9] proposed that the mechanism of rotational circulation is akin to the Magnus effect, which is responsible for the lift production of translating and rotating a blunt body. Later, Sane [10] clarified that it was due to the Kramer effect and that the Magnus force mechanism applies only to blunt bodies, such as cylinders and spheres.
The theory of the Magnus effect is well-known [14]. When an object rotates clockwise, as it translates from left to right, the velocity under the body will decrease, while that above it will increase. As a result, the pressure above the sphere is smaller than that under the body, leading to increased lift. The opposite effect occurs when the direction or the rotation is reversed. This effect on the blunt body is illustrated in Figure 1b. Nonetheless, the actual contribution of these two effects on total lift generation is unclear, particularly when they are both observable in some transition cases, such as for a wing section profile between blunt and sharp.
Most of the experimental work describes the unsteady nature of rotational lift production qualitatively and quantitatively. However, quantitative results are often incomplete due to the complexities of flow visualizations and limitations in conducting experiments. In these cases, a numerical approach helps visualize the flow to spatially obtain the generated force. Wang et al. recommended a two-dimensional approach to provide a reasonable approximation of insect flight [15]. In performing numerical simulations, the main difficulties include handling moving mesh, maintaining high mesh quality around the moving wing, particularly during large rotations, and managing complex flow problems. A Radial Basis Function mesh motion solver can solve the translation and rotational motion of the wing. However, complex flow problems require an advanced method, such as the immersed boundary method or the fluid–structure interaction method.
The objective of this study was to analyze the lift production of a rotating and translating wing by employing combined experimental and numerical approaches. By varying the wing section profile from a circular cylinder to a proper thin wing, the change in rotational lift production was observed. Furthermore, qualitative results were obtained through flow visualization. Combined experimental and computational analysis was conducted, leading to interesting conclusions regarding the transition between the Magnus effect (for blunt bodies) and the Kramer effect (for sharp bodies). The computational results were validated using the experimental results and offer insight into the unsteady aerodynamics of insect flight to verify the experimental results.

2. Experiment

2.1. Experiment Description

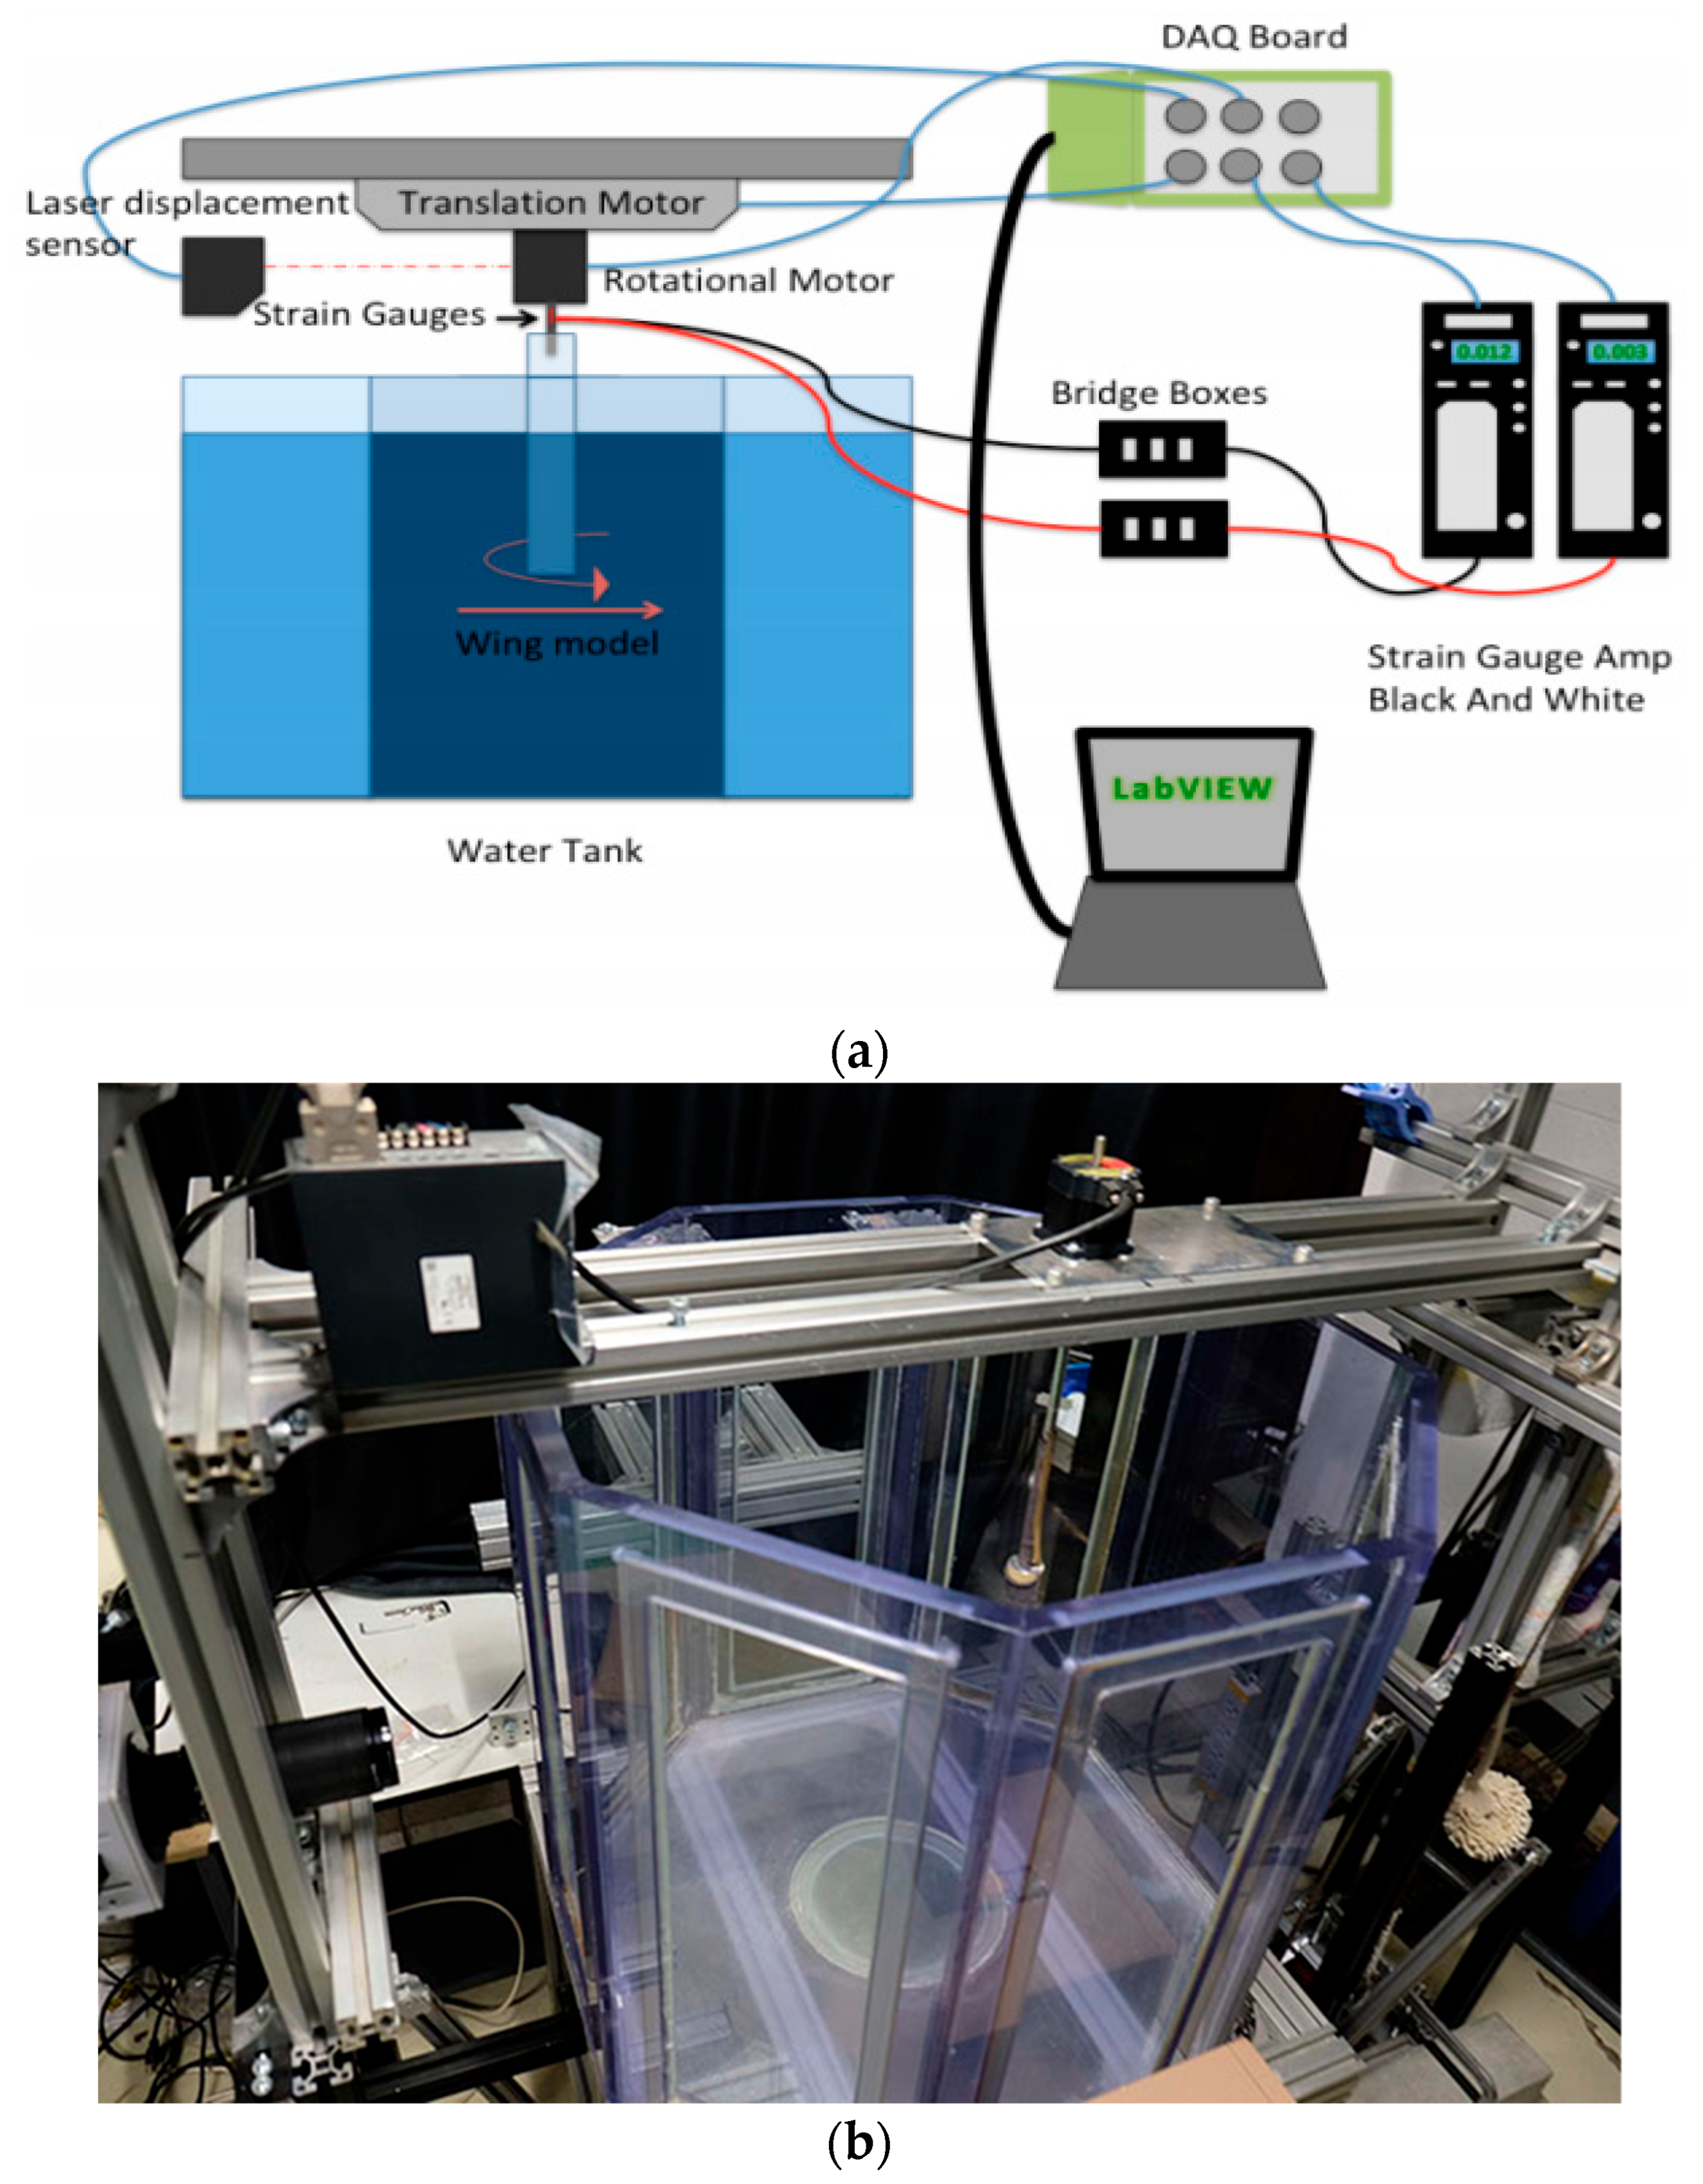
To study rotational lift, simplified flapping wing conditions in bumblebees were recreated. With a Reynolds number of 1200 and an aspect ratio of 4, the bumblebee is a good representation of small flyers, which generally have a Reynolds number between 101 and 104. Because it is difficult to reach such high velocities with such small wings, the experiment consisted of symmetrically translating and rotating a wing soaked inside of a water tank. The experimental setup is shown in Figure 2. For mechanical features, the wing was fixed vertically, and only 2 dimensions were considered. Because the study was focused on an unsteady effect, it was important to choose appropriate unsteady motions encountered in real insect flight.
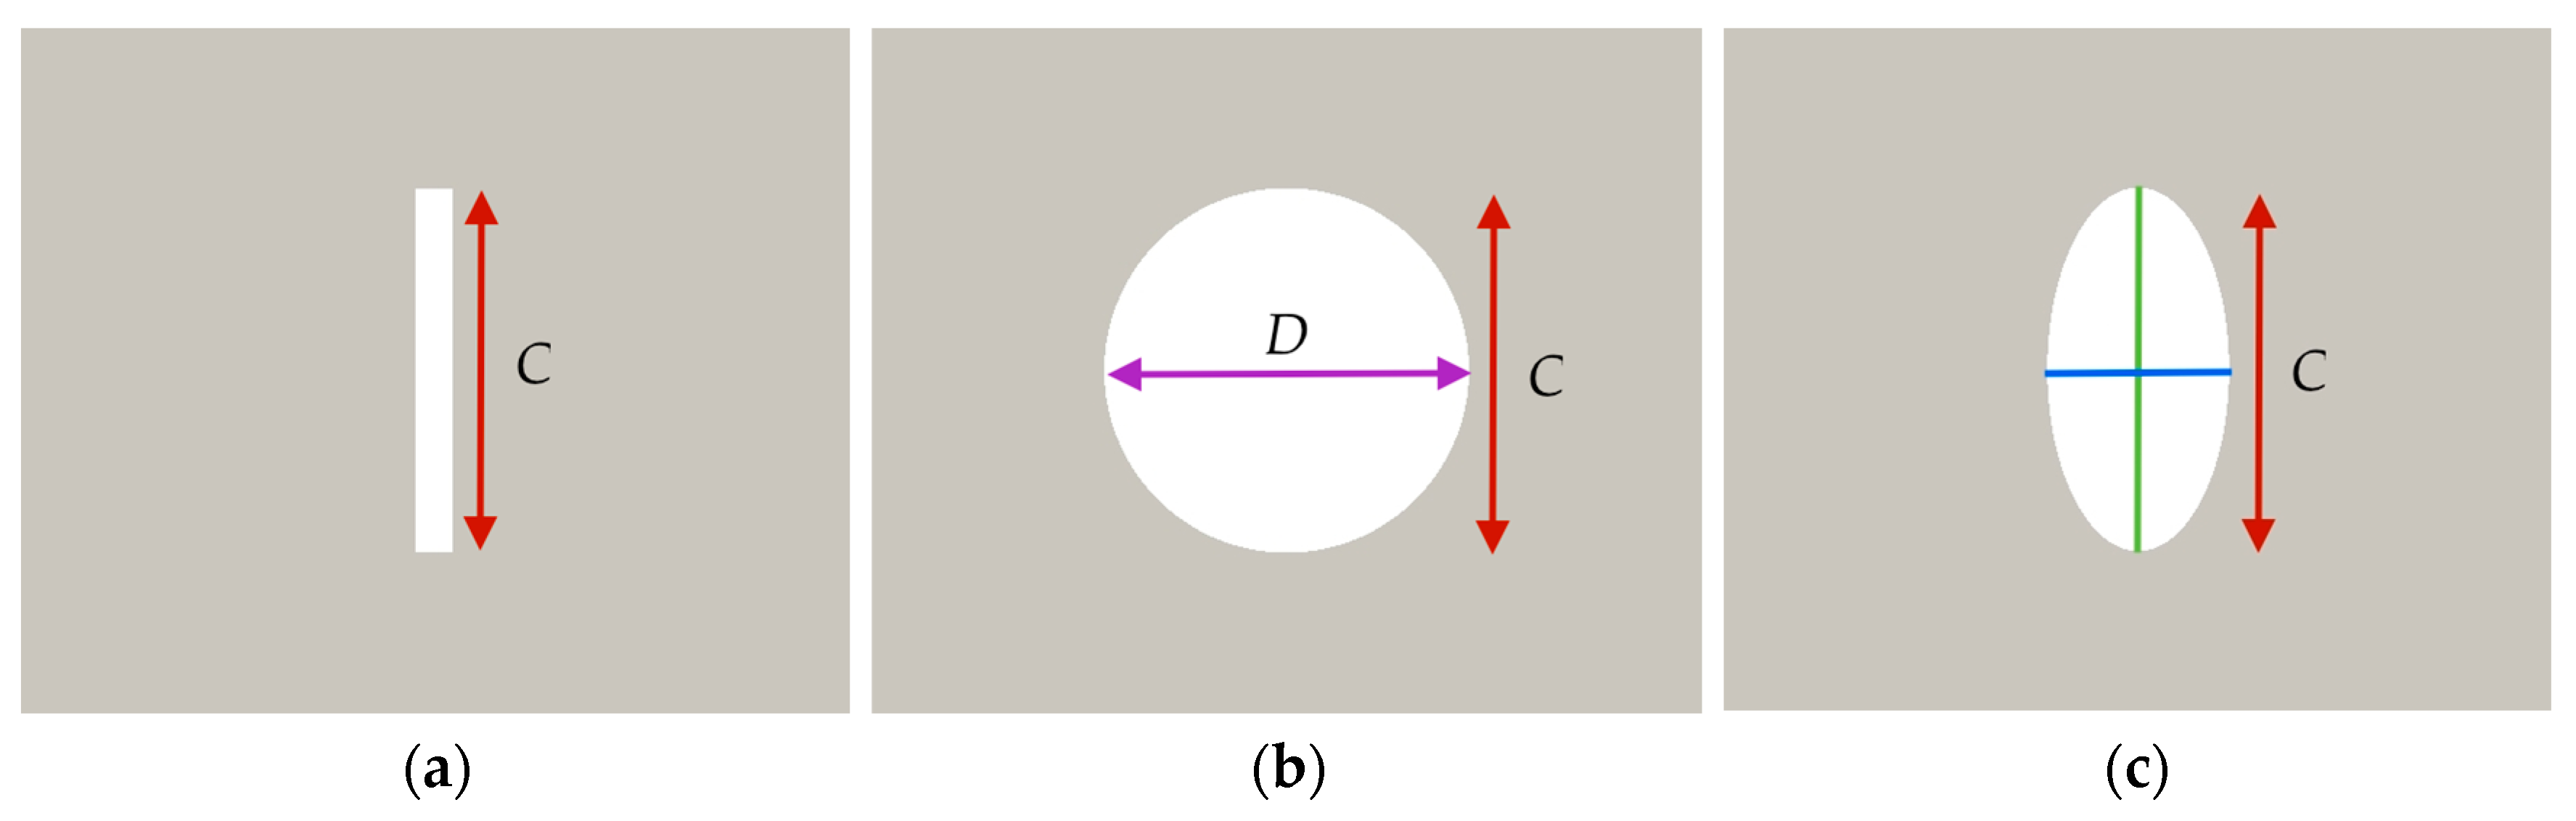
Regarding the wing section profile, we analyzed 3 different wing section profiles as shown in Figure 3, using a flat plate model as the sharp body reference, a circular cylinder model as the blunt body reference, and an elliptical cylinder model as a transition case. By moving through the water, a thin cylinder located between the wing and the motor was deformed. Therefore, two strain gauges were fixed to it to measure the deformation in two perpendicular directions. After manipulating the raw data, the lift and drag production were found.
Next, we analyzed the qualitative results by conducting a particle image velocimetry experiment to better understand the surrounding flow structure. To reach a fully developed flow, 32 cycles were conducted. However, 15 cycles were sufficient. Direct force measurement relied on an average of the 18th last cycles, while particle image velocimetry analysis included one half cycle, as the 18 last cycles were similar and we reached a fully developed flow.

2.2. Flapping Motion

To recreate bumblebee flight conditions [16], we used a Reynolds number, Re, of 1200.
Re = (VxmaxC)/νw
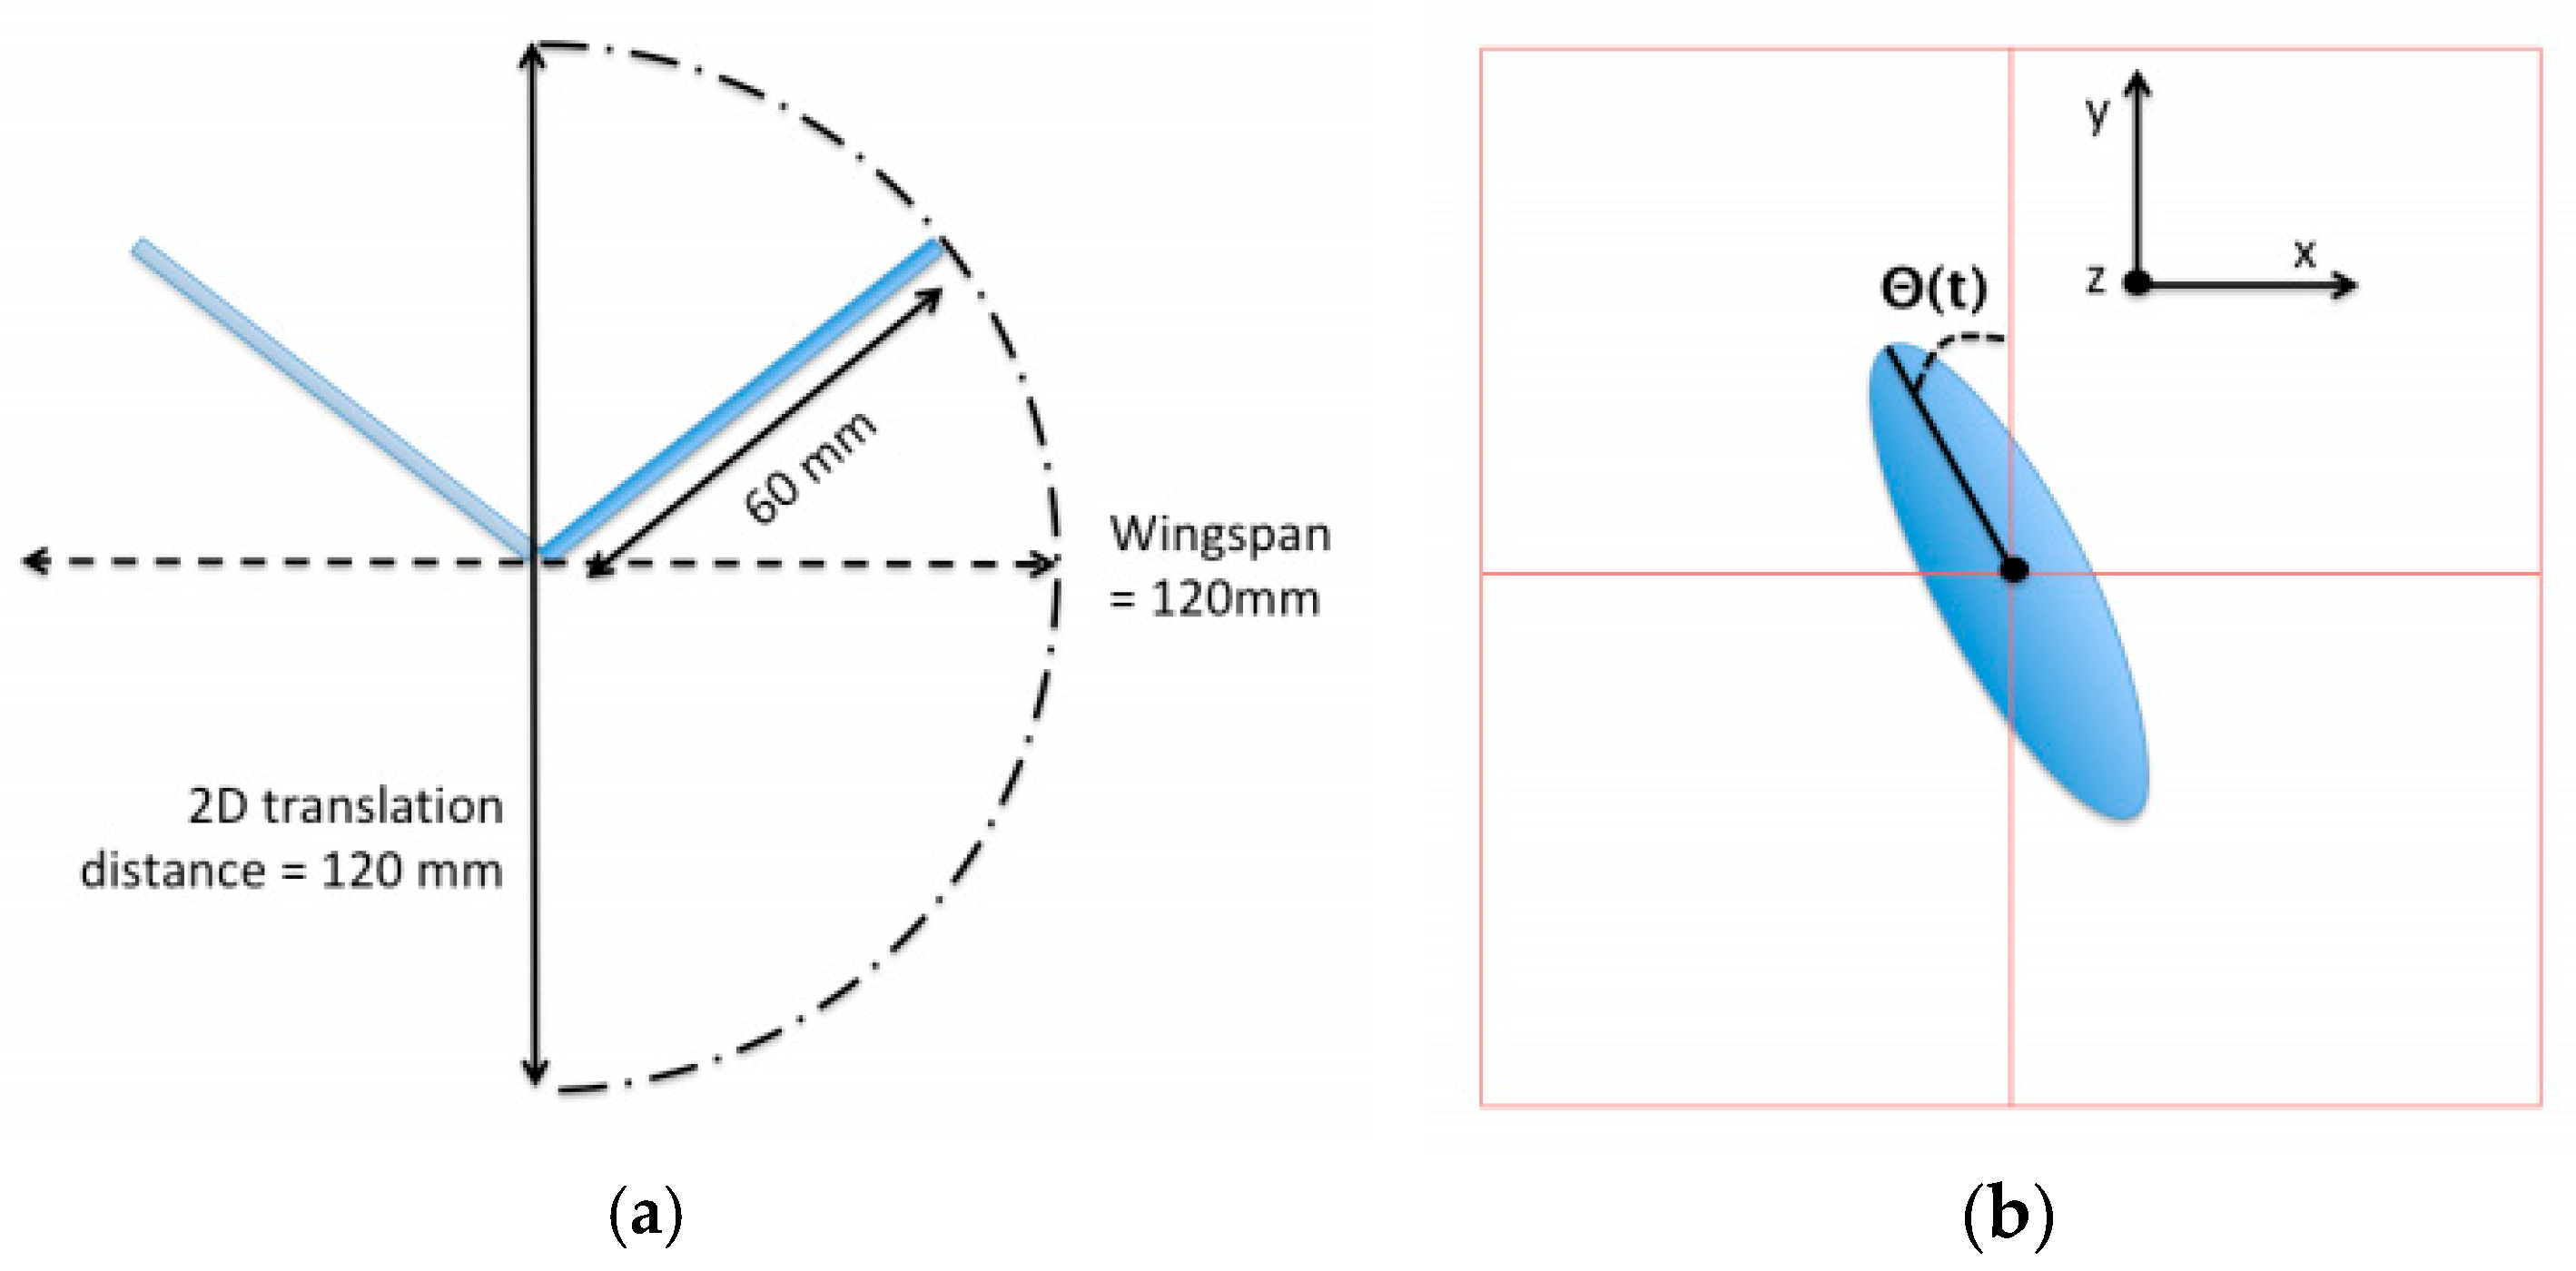
where Vxmax is the maximum translational velocity, C is the chord length of the wing, and νw is the kinematic viscosity of water at 20 °C, with a value of 1.0035 × 10⁻⁶ m2/s. For mechanical features, we chose a chord length of 30 mm, which leads to a maximum translational velocity Vxmax of 40.1 mm/s. With an aspect ratio AR = b/C of 4, we obtained a wingspan, b, of 120 mm and a theoretical wing length of 60 mm. Therefore, the 2D translation distance can be assumed to be 120 mm, as explained in Figure 4a. However, in practice, the actual wing length soaked in water was 160 mm to increase the total force applied on the wing and to reduce the 3-dimensional effects.
A precise definition of the coordinates is provided in Figure 4b. The rotational and translational velocity profiles were based on real insect flight and Willmott and Ellington’s results [17]. The change in sweep angle, as well as the change in angle of rotation, mostly follow a sinusoidal trend. Hence, their derivative, translational and rotational velocity, is defined as a sinusoidal function. To produce a symmetrical movement, the maximum rotational velocity occurs when the translational velocity equals 0 mm/s at x = 0 mm and x = 120 mm and when θ, the angle of rotation, equals 0°. On the other hand, the maximum translational velocity occurs when the rotational velocity equals 0 rad/s at x = 60 mm and when θ = 90°. Therefore, we obtain the following position profiles:
θ(t) = (π/2) sin(2πt/p),
x(t) = −60 cos(2πt/p),
The position profile x is for the translational motion and the position profile θ is for the rotational motion. By differentiating the equations of the two position profiles with respect to time, we can derive the following two velocity profiles:
Vr(t) = Vrmax cos(2πt/p),
Vx(t) = Vxmax sin(2πt/p),
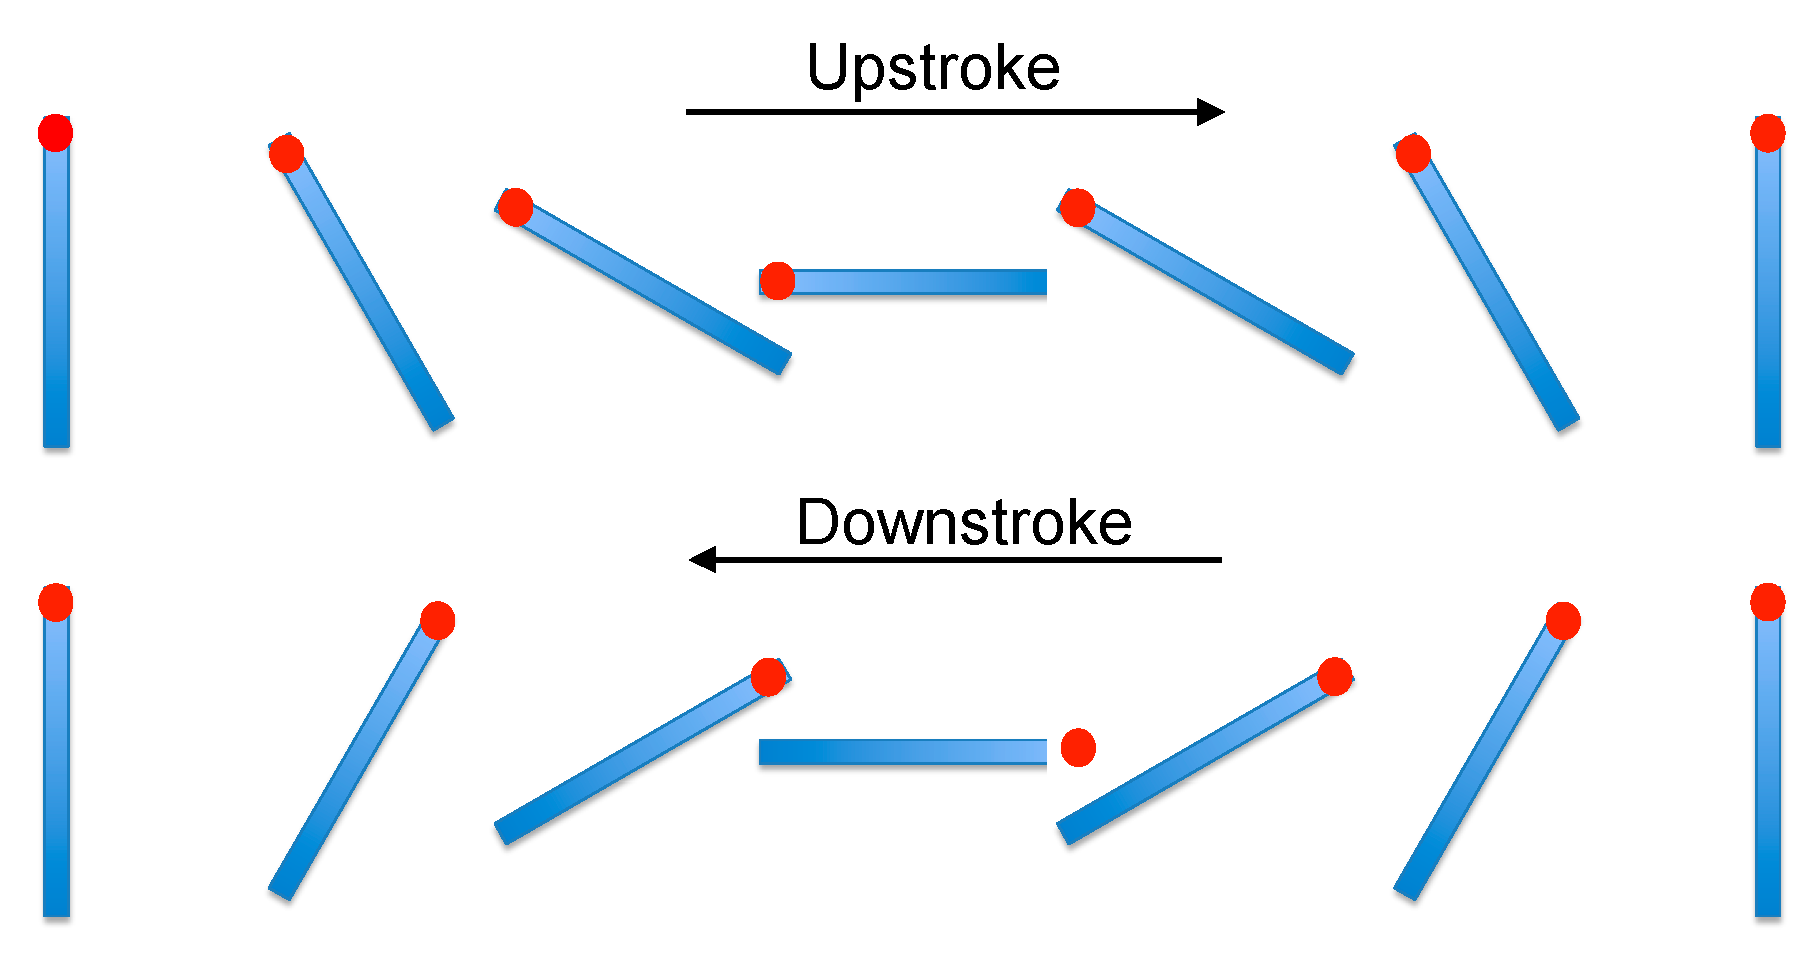
where p = 9.4 s is the flapping period, the amount of time needed to achieve one round trip, Vxmax = 60 × (2π/p) = 40.1 mm/s or 4.01 cm/s, and Vrmax= (π/2) × (2π/p)= 1.05 rad/s. The velocity profile Vx(t) is for the translational velocity and the velocity profile Vr(t) is for the rotational velocity. The wing position along the whole stroke is illustrated in Figure 5. The dimensionless time is defined as t^ = t/T = 2t/p, where the reference amount of time T = p/2 is the duration of one downstroke or upstroke.
The Reynolds number, Re, Strouhal number (St), rotation amplitude, rotation period, and center of rotation are provided in Table 1. According to the literature, the Strouhal number (St), a dimensionless number describing oscillating flow mechanisms, is fairly constant at around 0.2 in the wide range of Reynolds numbers (500 < Re < 2105) for a cylinder.

2.3. Equipment

2.3.1. Water Tank

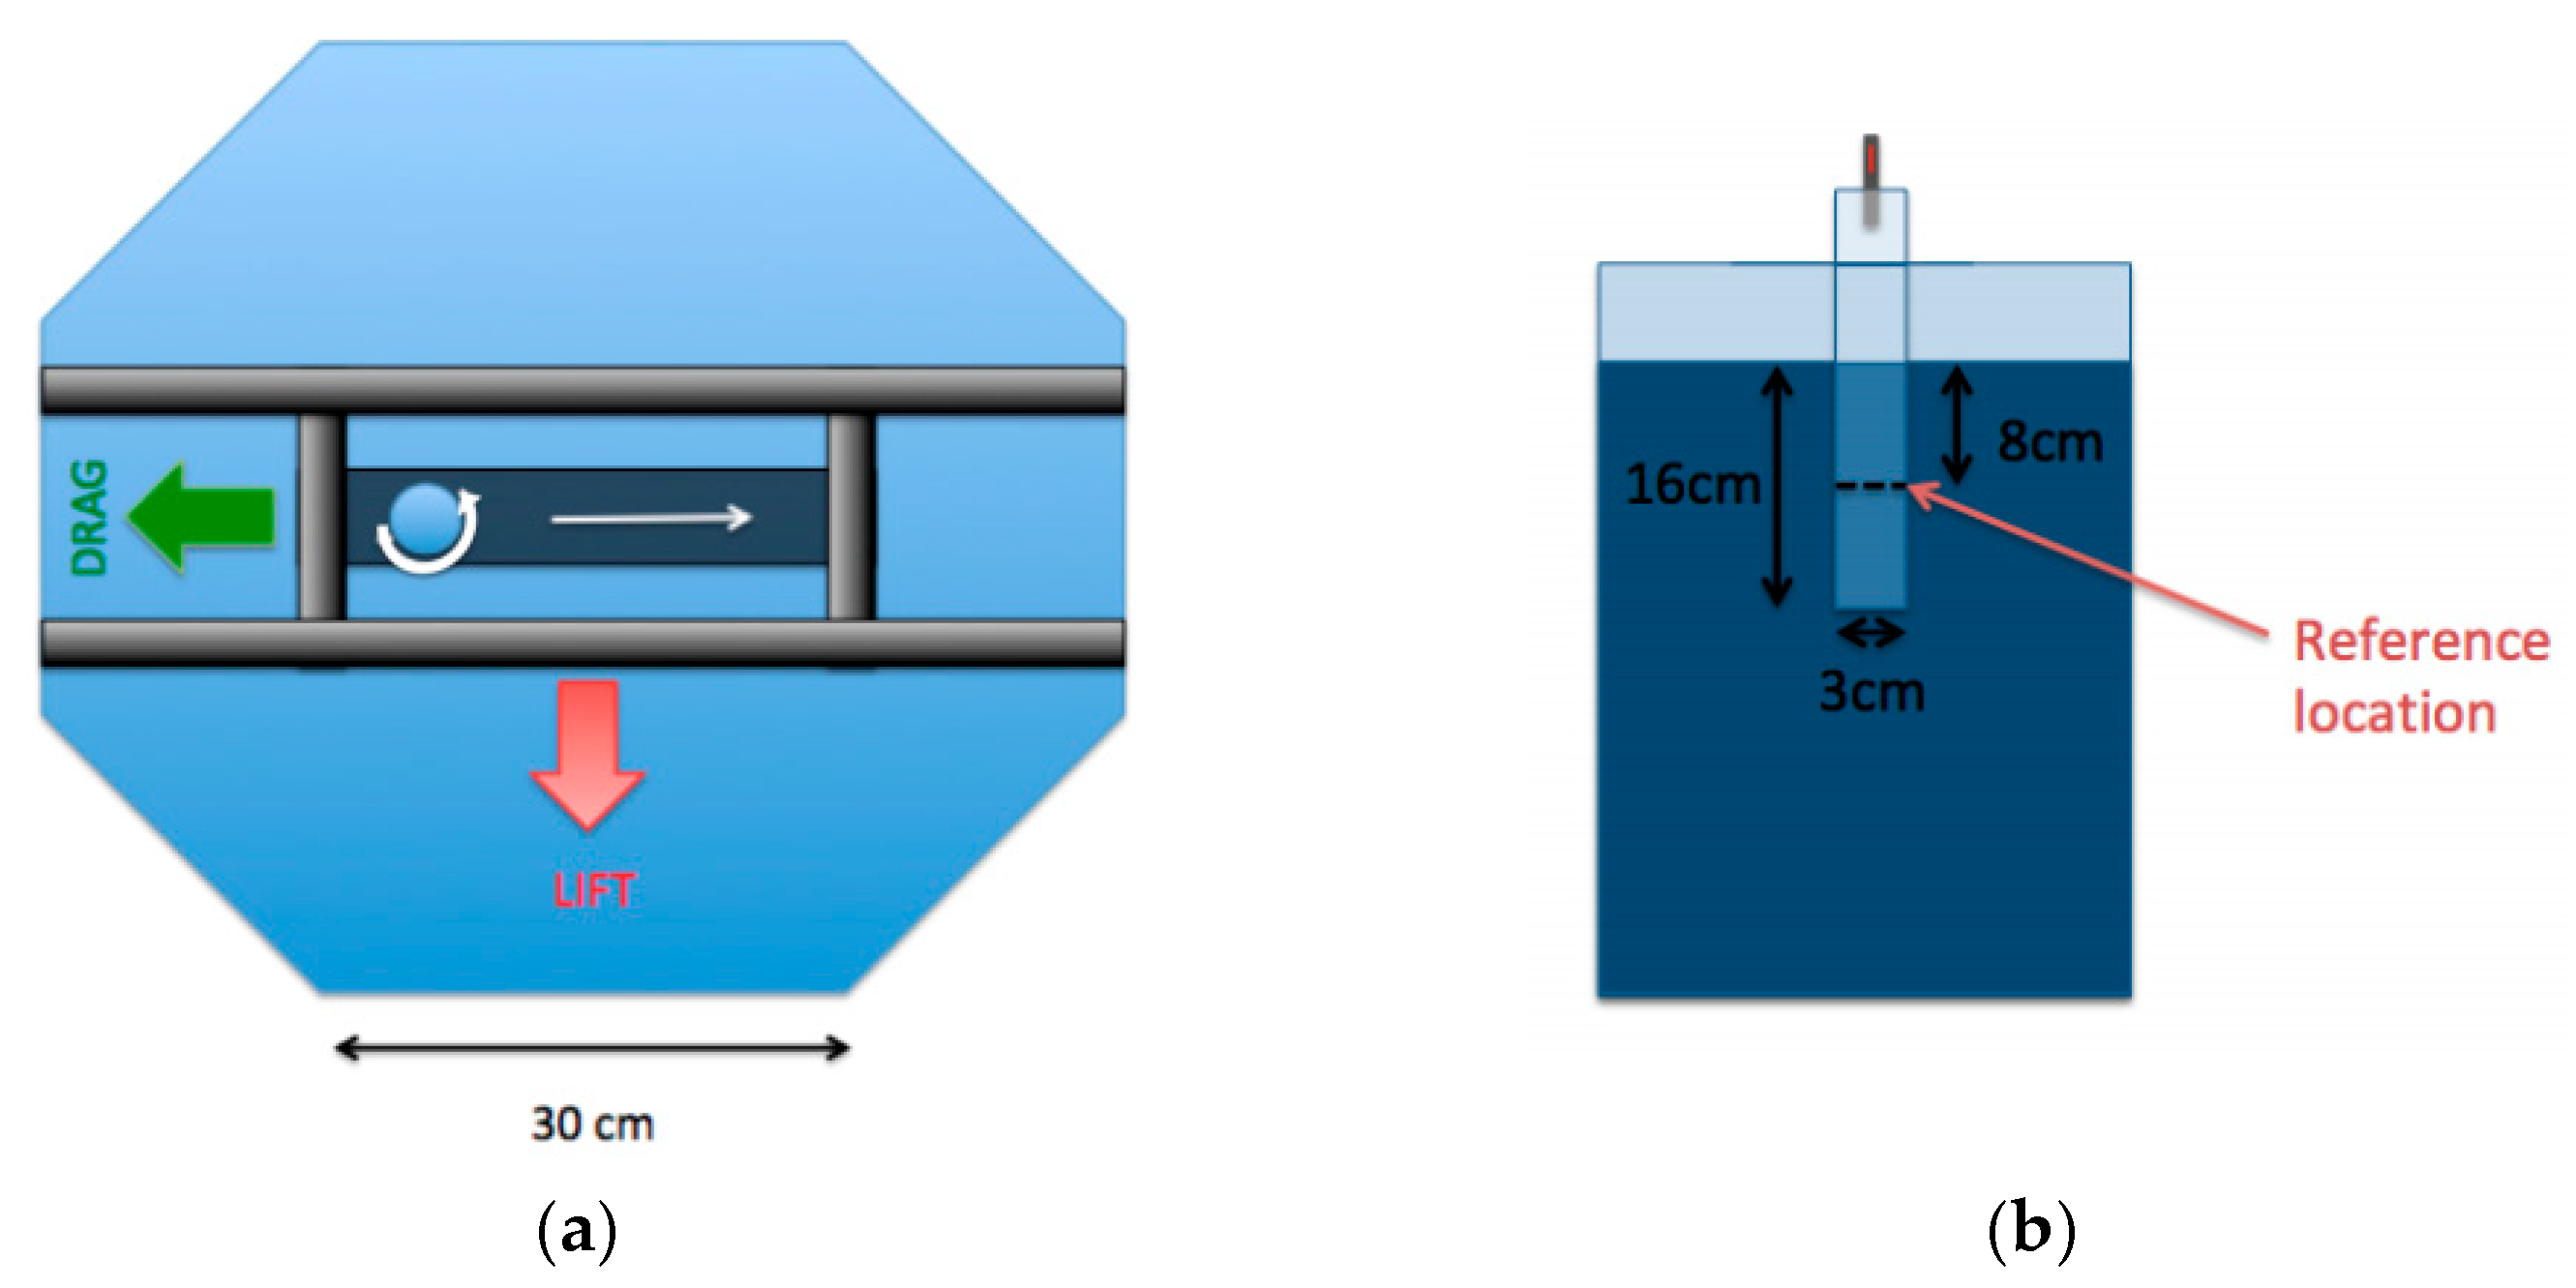
Water was chosen as the surrounding fluid to reduce the velocity and increase the reference length while keeping the same Reynolds number. Furthermore, water is a convenient choice to conduct flow visualizations. The tank used is represented in Figure 6a. It was an octagon that measured 30 cm on each side with a 70 cm depth. The walls were 1 cm thick. These dimensions allowed us to ignore wall effects. On top of the tank, 2 rails were fixed to mount the motors.

2.3.2. Motors

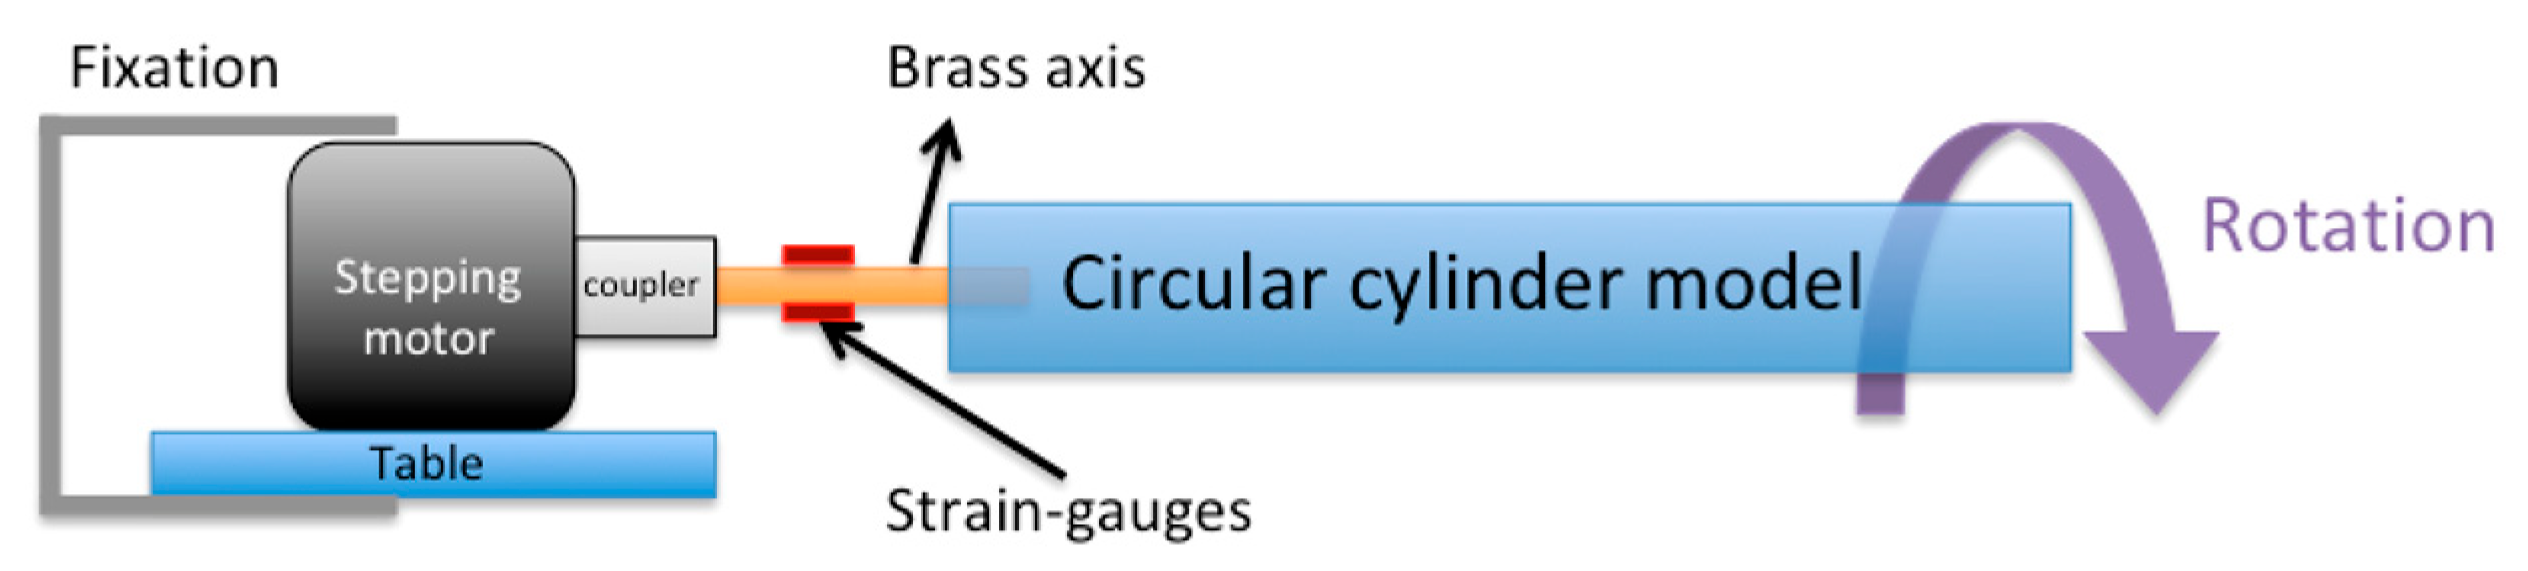
For translational and rotational motion, a ball screw electric slider and a stepping motor were used. Their specifications aligned with the motion and the power required. To validate the rotation motion, we first tried to use a potentiometer. After several attempts, we concluded that the potentiometer was less accurate than the motor itself and that the output angle read directly from the motor was correct. For the translation motion, we used a laser displacement sensor.

2.3.3. Wings

Real insect wings are not rigid or smooth. As such, their surface texture and flexibility can significantly influence their aerodynamic performance. In addition, these aerodynamic characteristics are closely related to the wings’ morphology, such as their thickness, local corrugation, and camber.
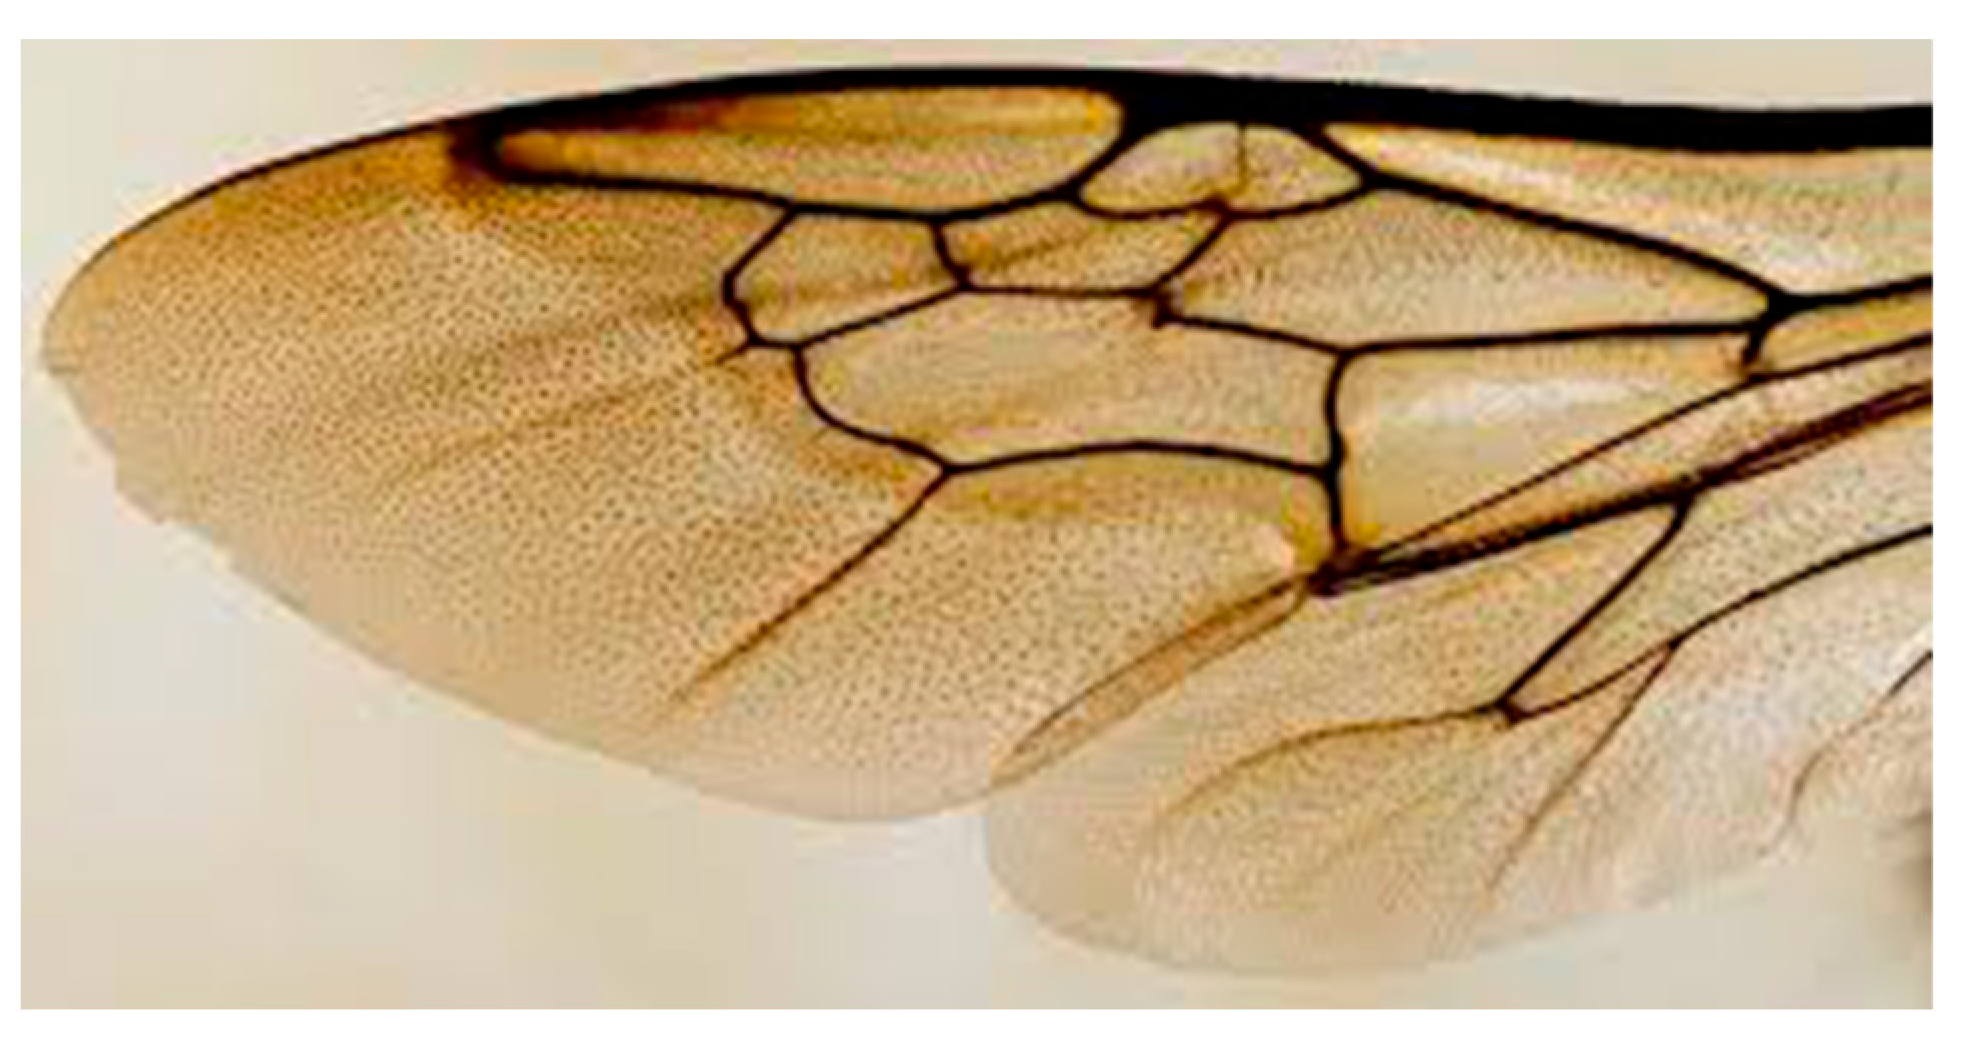
In this study, we present an investigation of the rotational lift production of a rigid translating and rotating wing using a Reynolds number of 1200 of a bumblebee. As shown in Figure 7, bumblebee wings are naturally cambered and corrugated. In this case, the wing’s cross-section can be approximated as a plane surface without cambered geometry. Most studies on insect flapping flight regard the flat plate model as the most common and simplest form. Hence, we first selected the flat plate model as a simplified model with uniform thickness, neglecting both local corrugation and the camber effect. Because our interest was rotational lift production, we then selected the circular cylinder model to identify the Magnus effect by comparing it with the Kramer effect of the flat plate model. Finally, the elliptical cylinder model was selected as a transition case between the flat plate and the circular cylinder models.
Three types of wing models with a 30 mm chord length were manufactured to compare the lift and drag responses: a circular cylinder model, a flat plate model, and an elliptical cylinder model. All were machined out of acrylic material and polished to clarify the surface. Acrylic material was chosen so that the laser could go through the model during flow visualization measurements. However, because the laser sheet converges behind the cylinder, some tracer particles within those shaded areas cannot be seen. Furthermore, each wing was immersed in 16 cm of water. Flow visualization and strain gauge calibration were conducted in the middle of the immersed part of the wing, 8 cm below the water’s surface (see Figure 6b). The different wing models are described hereafter.
  • Flat plate model
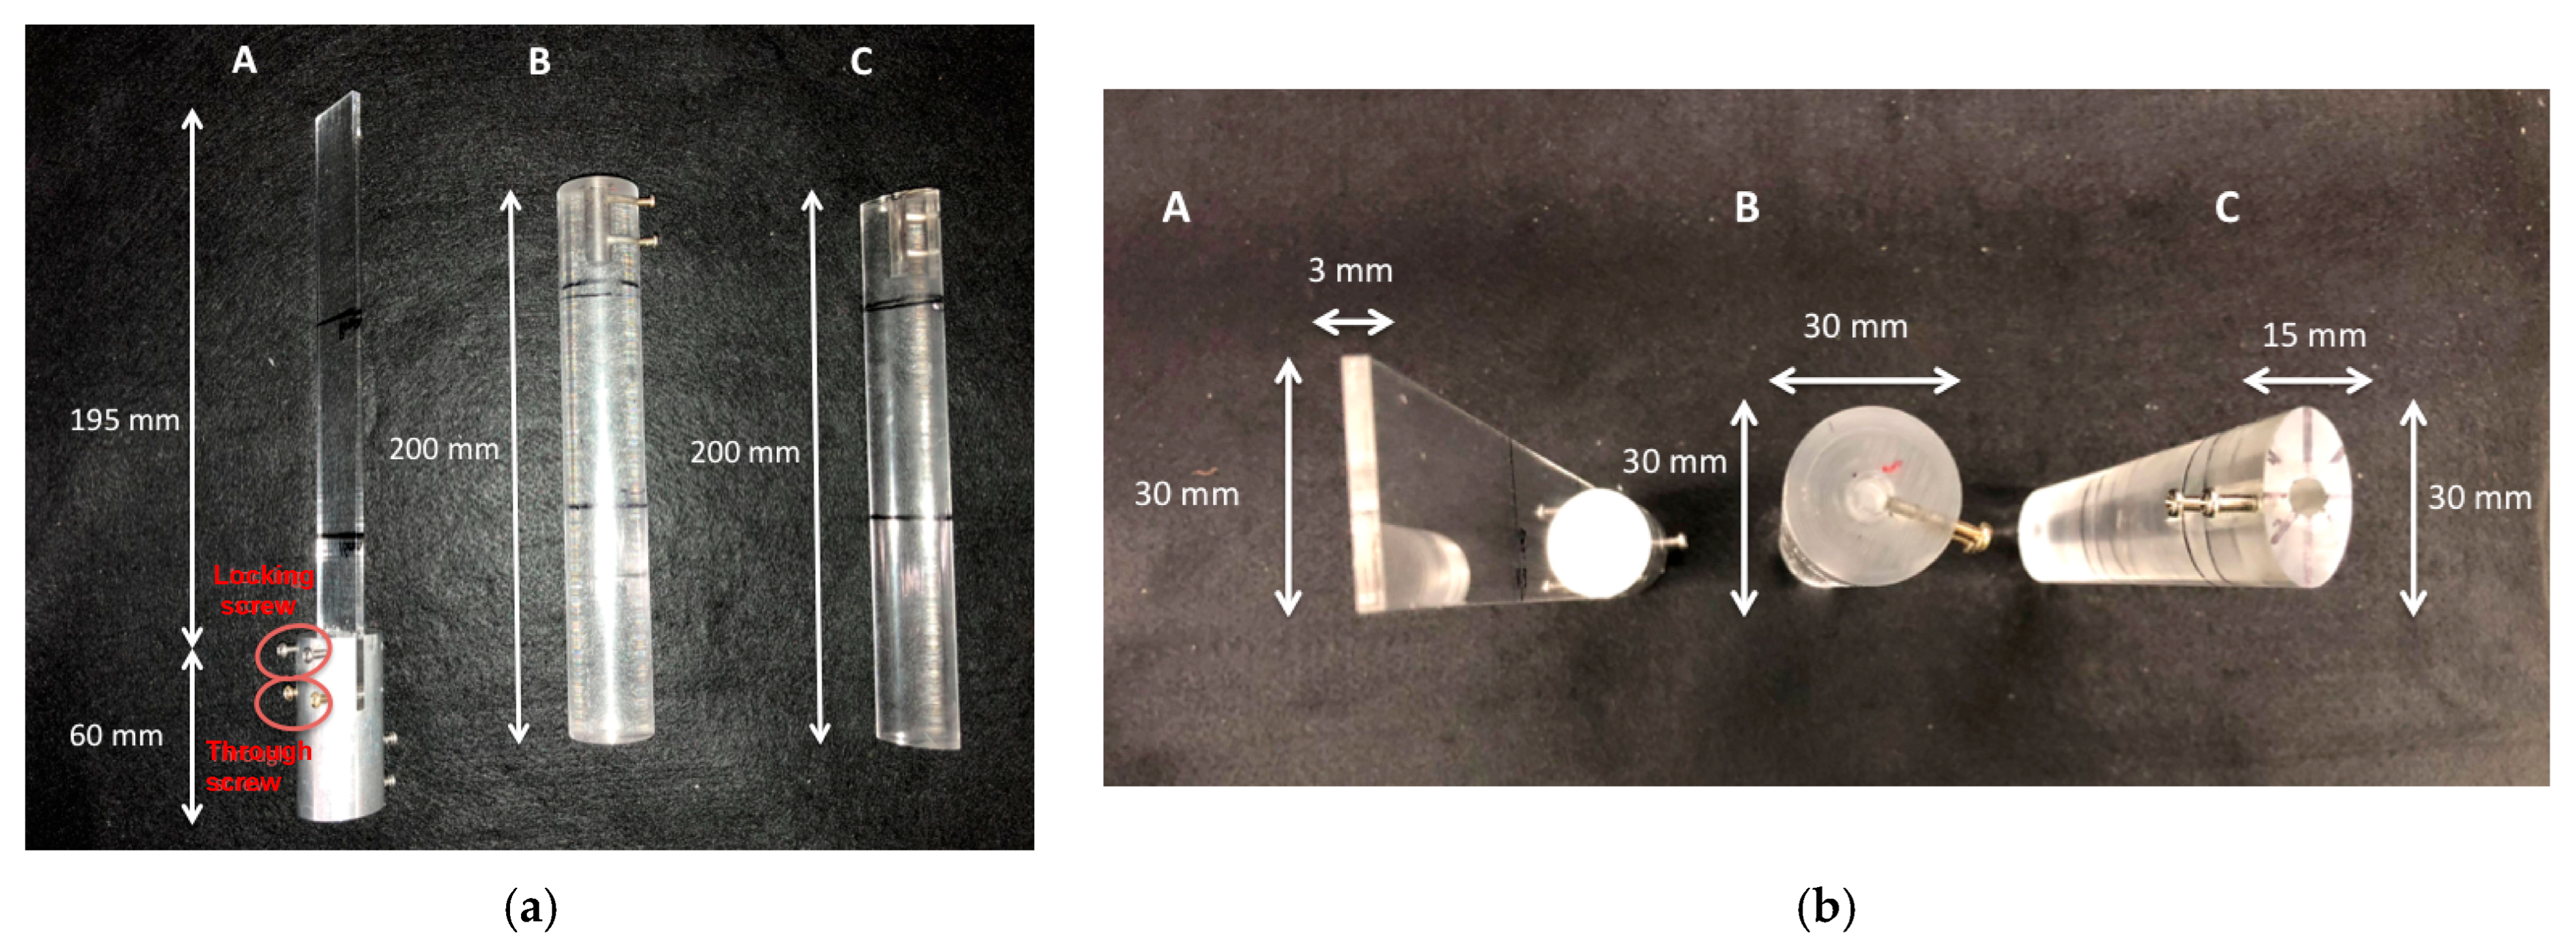
    The flat plate was clipped using a coupler, which fixes the model to the rotational axis shown in Figure 8 A. The plate had a chord length of 30 mm, with a total length of 220 mm, where 25 mm was located between the clips so that it was well-fixed. The plate model was 3 mm thick to avoid any elastic deformation while keeping it as thin as possible. The aluminum coupler piece was 30 mm in diameter and 80 mm in spanwise length. It had two holes for screws to hold the flat plate and two other holes for locking screws to tighten the plate. Finally, the two screws on the left side were used to fix the plate model on the brass rotational axis. With this model, the Kramer effect should be observed during supination and pronation.
  • Circular cylinder model
    The circular cylinder model, shown in Figure 8 B, served as a reference model, as it is assumed to produce a purely rotational effect, avoiding the complexity of the wing profile. The cylinder had a length of 200 mm and a diameter of 30 mm. The 30 mm depth hole on top, which was used to attach the rotational axis on which the strain gauges were attached, was 6 mm in diameter. Two tapped holes on the side near the top, which were 3 mm in diameter, were used to tighten the cylinder onto the rotational axis.
  • Elliptical cylinder mode
    The elliptical cylinder model, shown in Figure 8 C, had a shape between the flat plate model and the circular cylinder model. With a big axis of 30 mm, a small axis of 15 mm, and an eccentricity of e = √2, this model was used for comparisons to the circular cylinder model and the flat plate model. Its other mechanical specifications are similar to those of the circular cylinder model. We used this model to determine what effect and in what proportion is responsible for lift production, including, more precisely, rotational lift production in this transitional case.

2.3.4. Strain Gauges

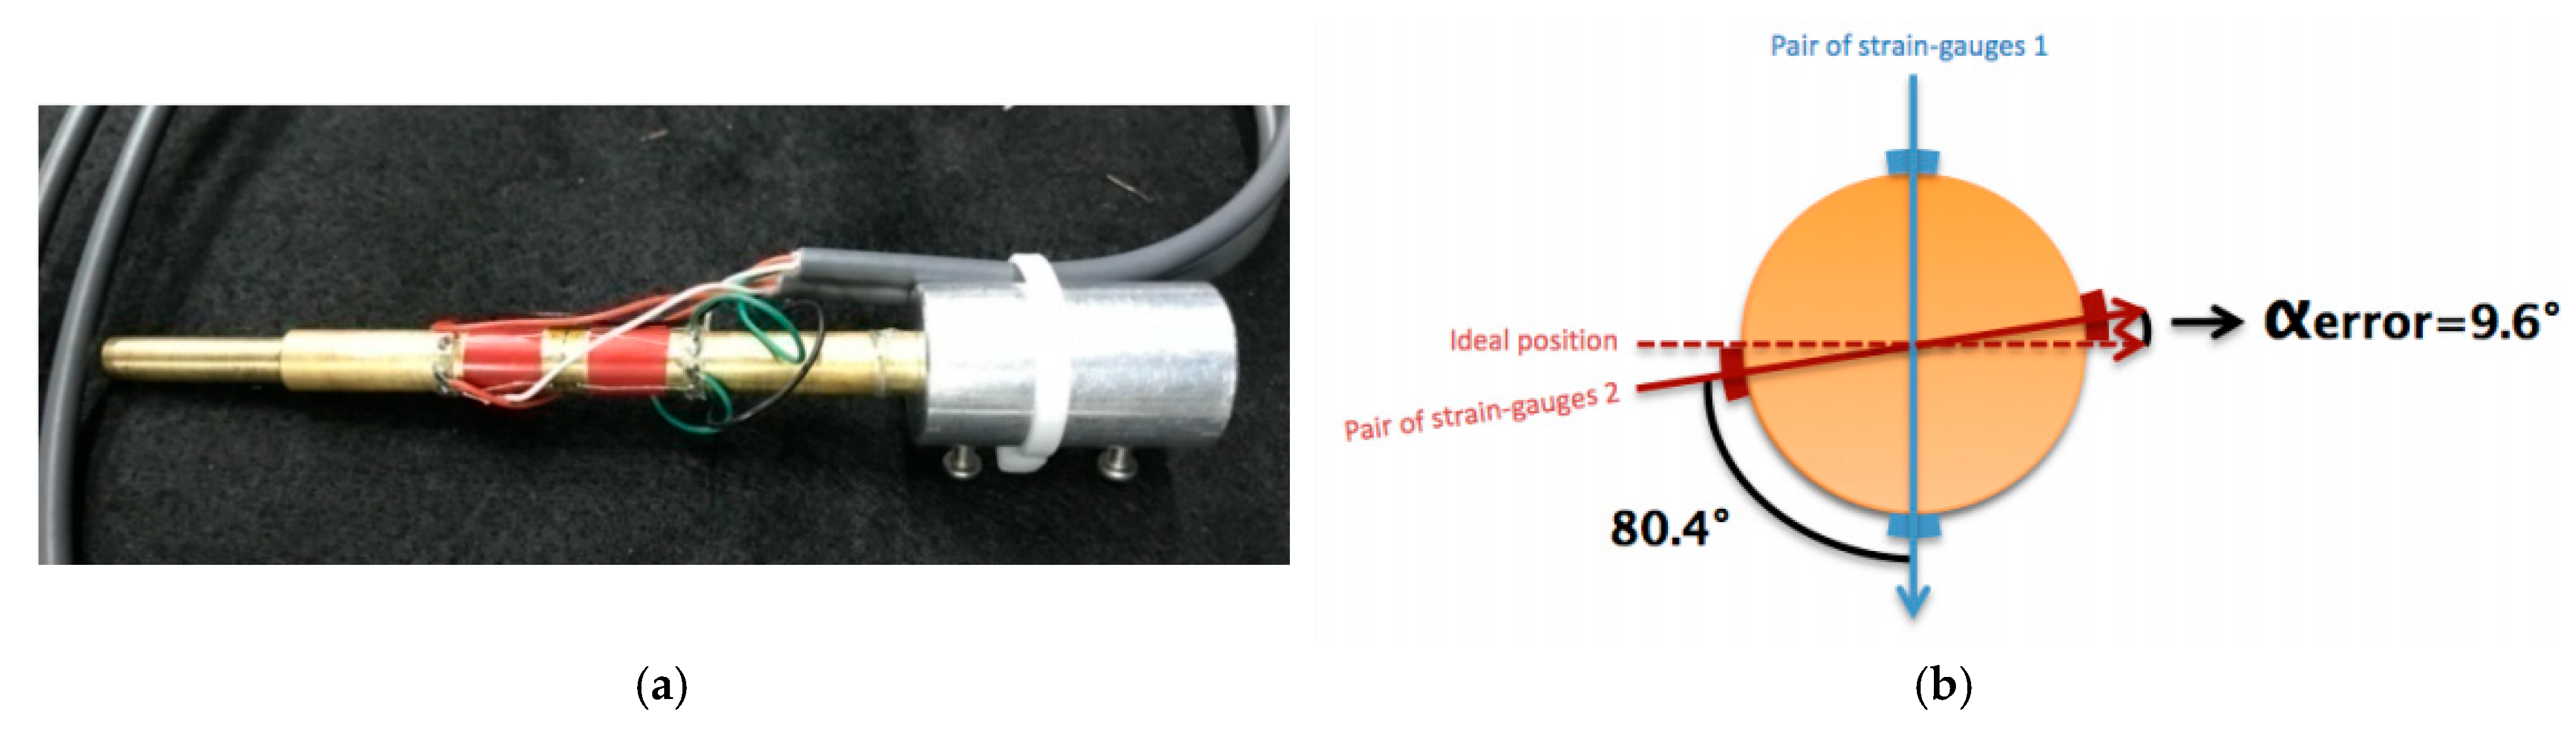
All wing models were designed to connect to an 8 mm diameter brass axis, shown in Figure 9a. The axis ended with a smaller section of 6 mm inserted into the wing model. The other extremity was fixed using two screws to a coupler, attached directly on the stepping motor. The total length of the axial connector was 115 mm, but only 80 mm was visible. Brass was chosen to avoid any plastic deformation. Two pairs of strain gauges mounted as an “active half-bridge system” were fixed to this cylinder to compute the drag and lift. Ideally, we intended for the pairs of strain gauges to be offset by 90°. Unfortunately, a small error of 9.6° remained, which is not a problem as long as that error is taken into account. The strain gauge configuration is shown in Figure 9b.

2.4. Direct Force Measurement

2.4.1. Strain Gauge Calibration

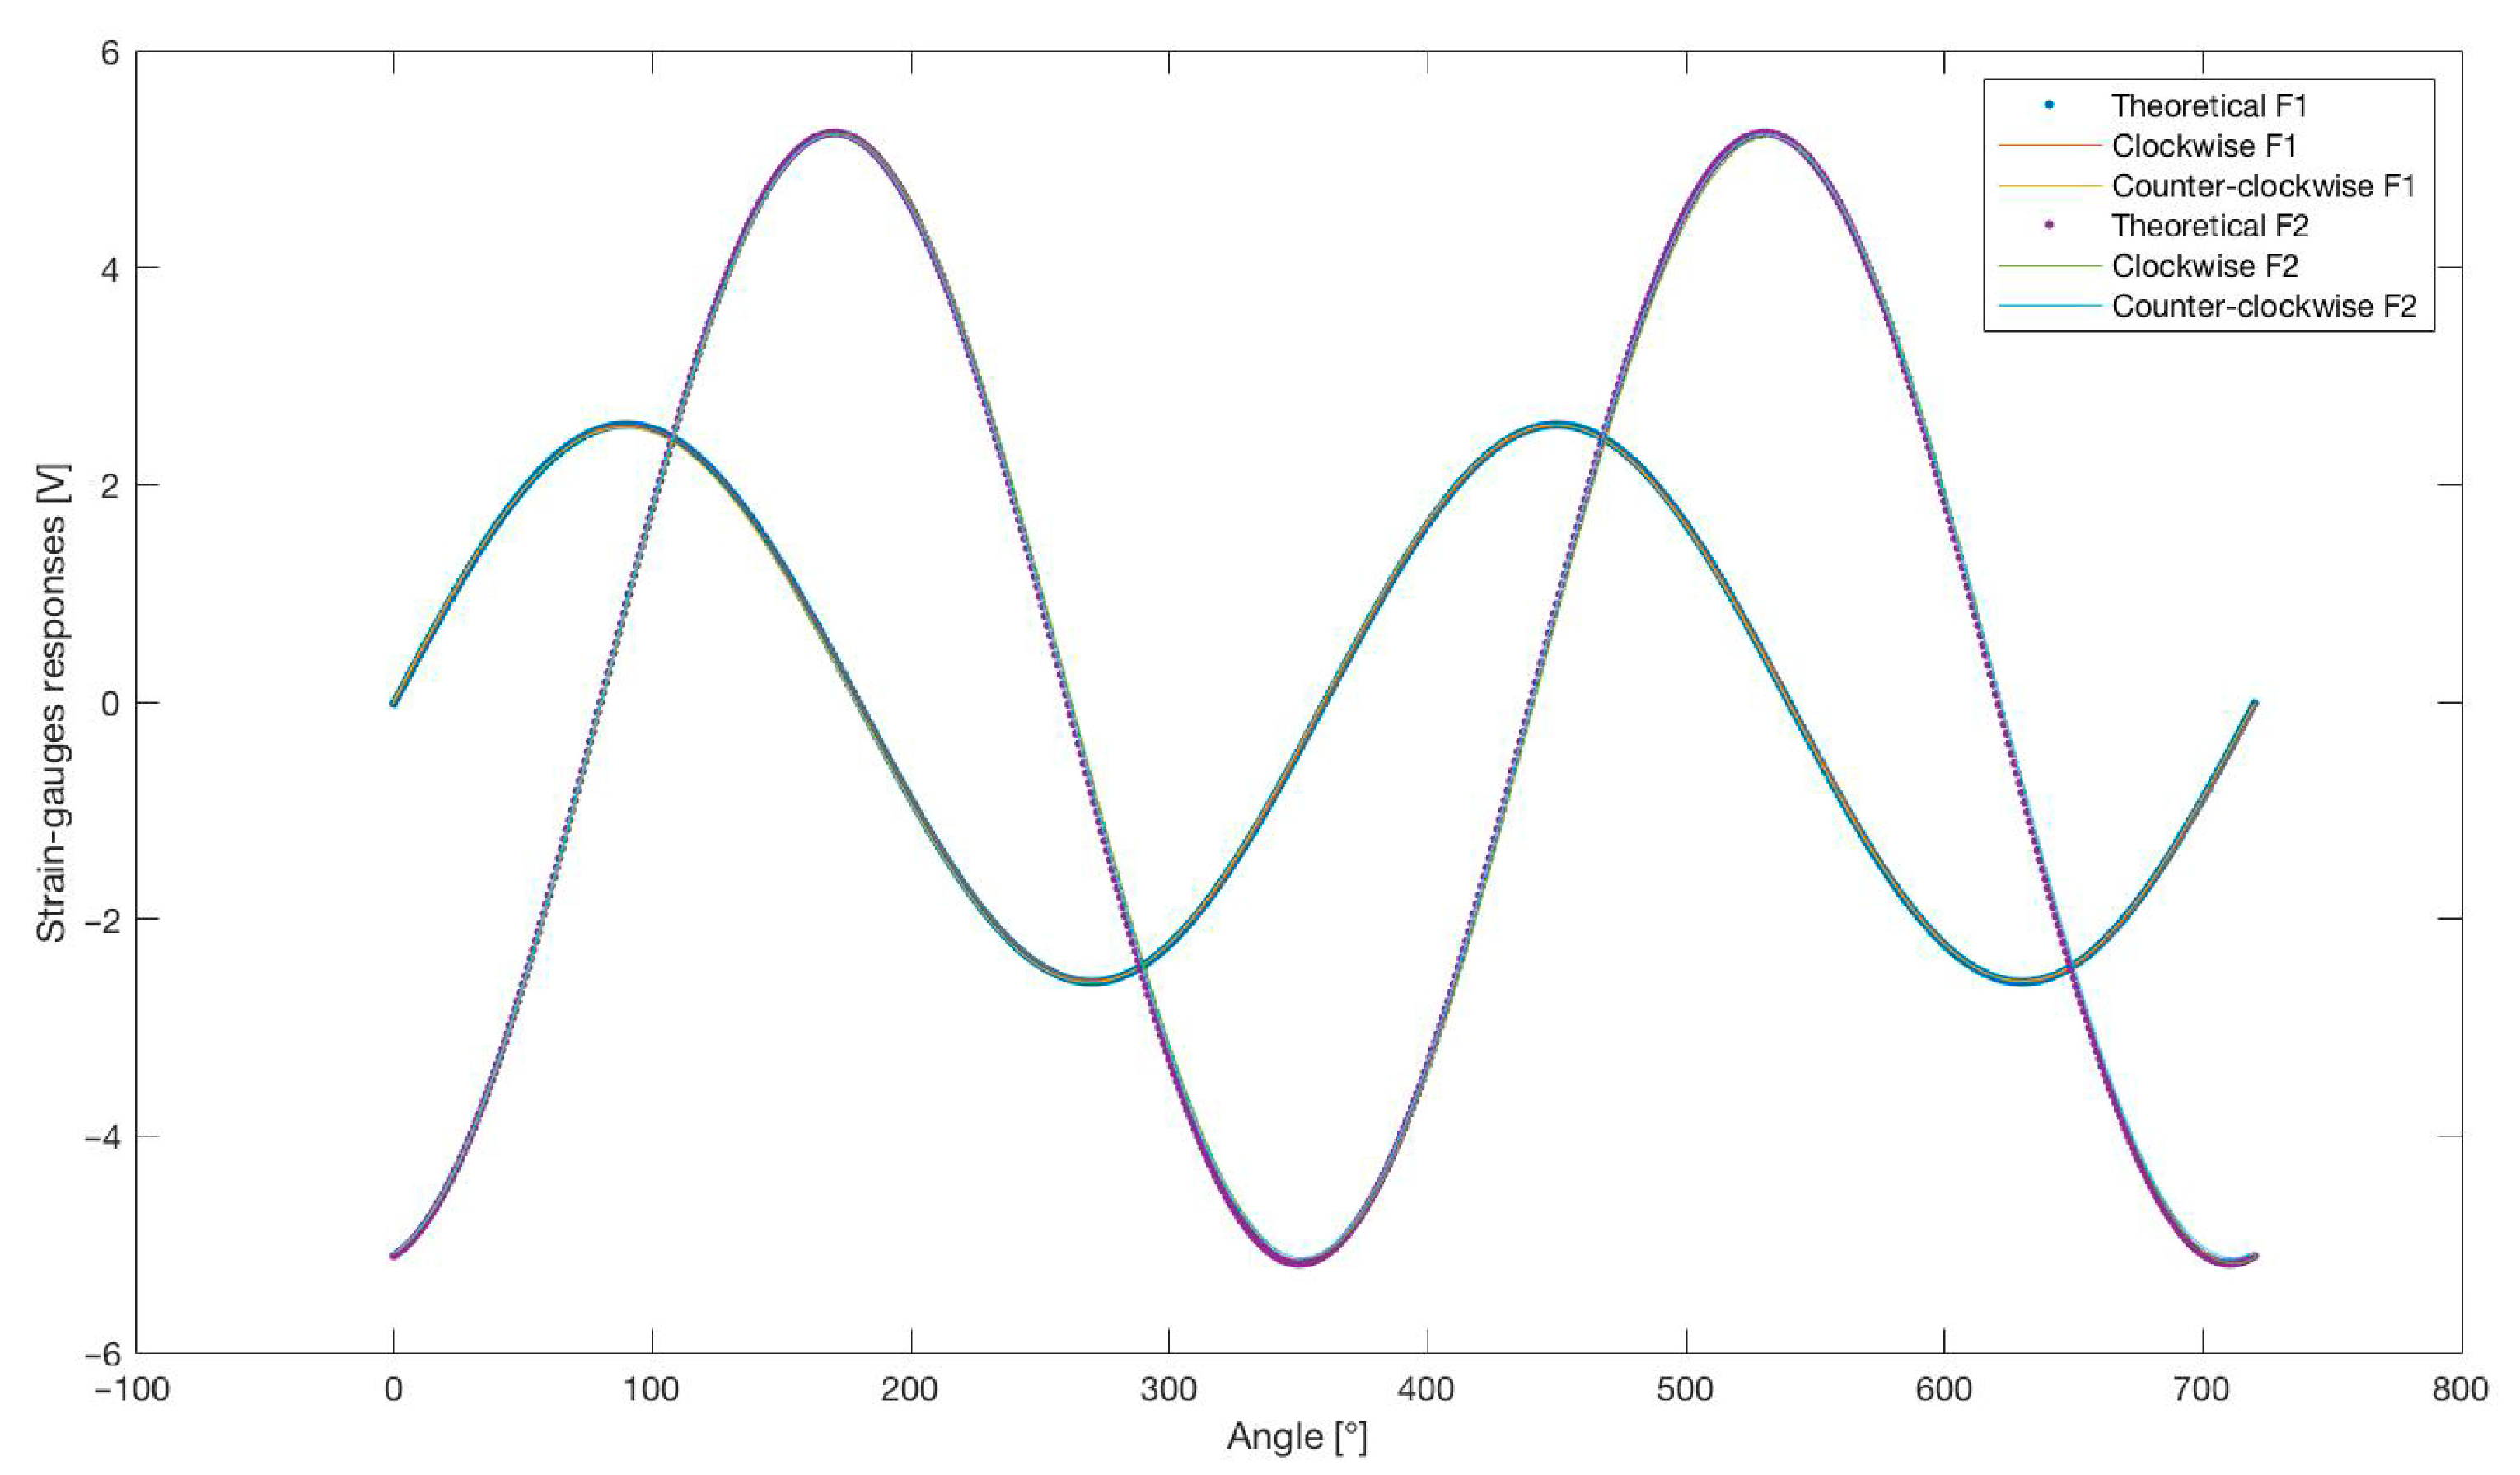
Calibration served two roles. First, we needed to find the αerror mentioned in Section 2.3.4 and validate the sinusoidal response of the strain gauges. Second, we needed to determine the correlation between the brass cylinder deformation, the voltage [V] read by the computer through the strain gauges, and the actual force applied on the wing [N] at the reference location (see Figure 6b). To do so, we had to find our “zeros,” the angle from which we observe a zero response regardless of the applied force, for both pairs of strain gauges. Logically, they should be perpendicular to the strain gauges’ axis. This was also a good opportunity to determine whether our strain gauges were well-mounted. The difference between 90° and the actual offset between the two respective “zeros” represents αerror. It was obtained as follows:
  • Let the brass axis hang freely with the circular cylinder model connected to it. Once completely at rest, process the strain gauges to a zero setting.
  • Connect the wing horizontally to the stepping motor, as described in Figure 10.
  • Using the motor, slowly turn the wing until a zero response is reached for one of the pairs of strain gauges.
  • Note the precise angle location.
  • Repeat steps 3 and 4 for the other pair of strain gauges.
  • Turn the wing slowly using the motor while reading both strain gauges’ responses.
The result of this procedure is shown in Figure 11. On this graph, the theoretical sinusoidal response fits perfectly with the clockwise and counter-clockwise responses for both pairs of strain gauges, where we used αerror = 9.6°. The amplitude difference is due to the parameters and mechanical features of the respective pairs of strain gauges and will be the focus of the second calibration.
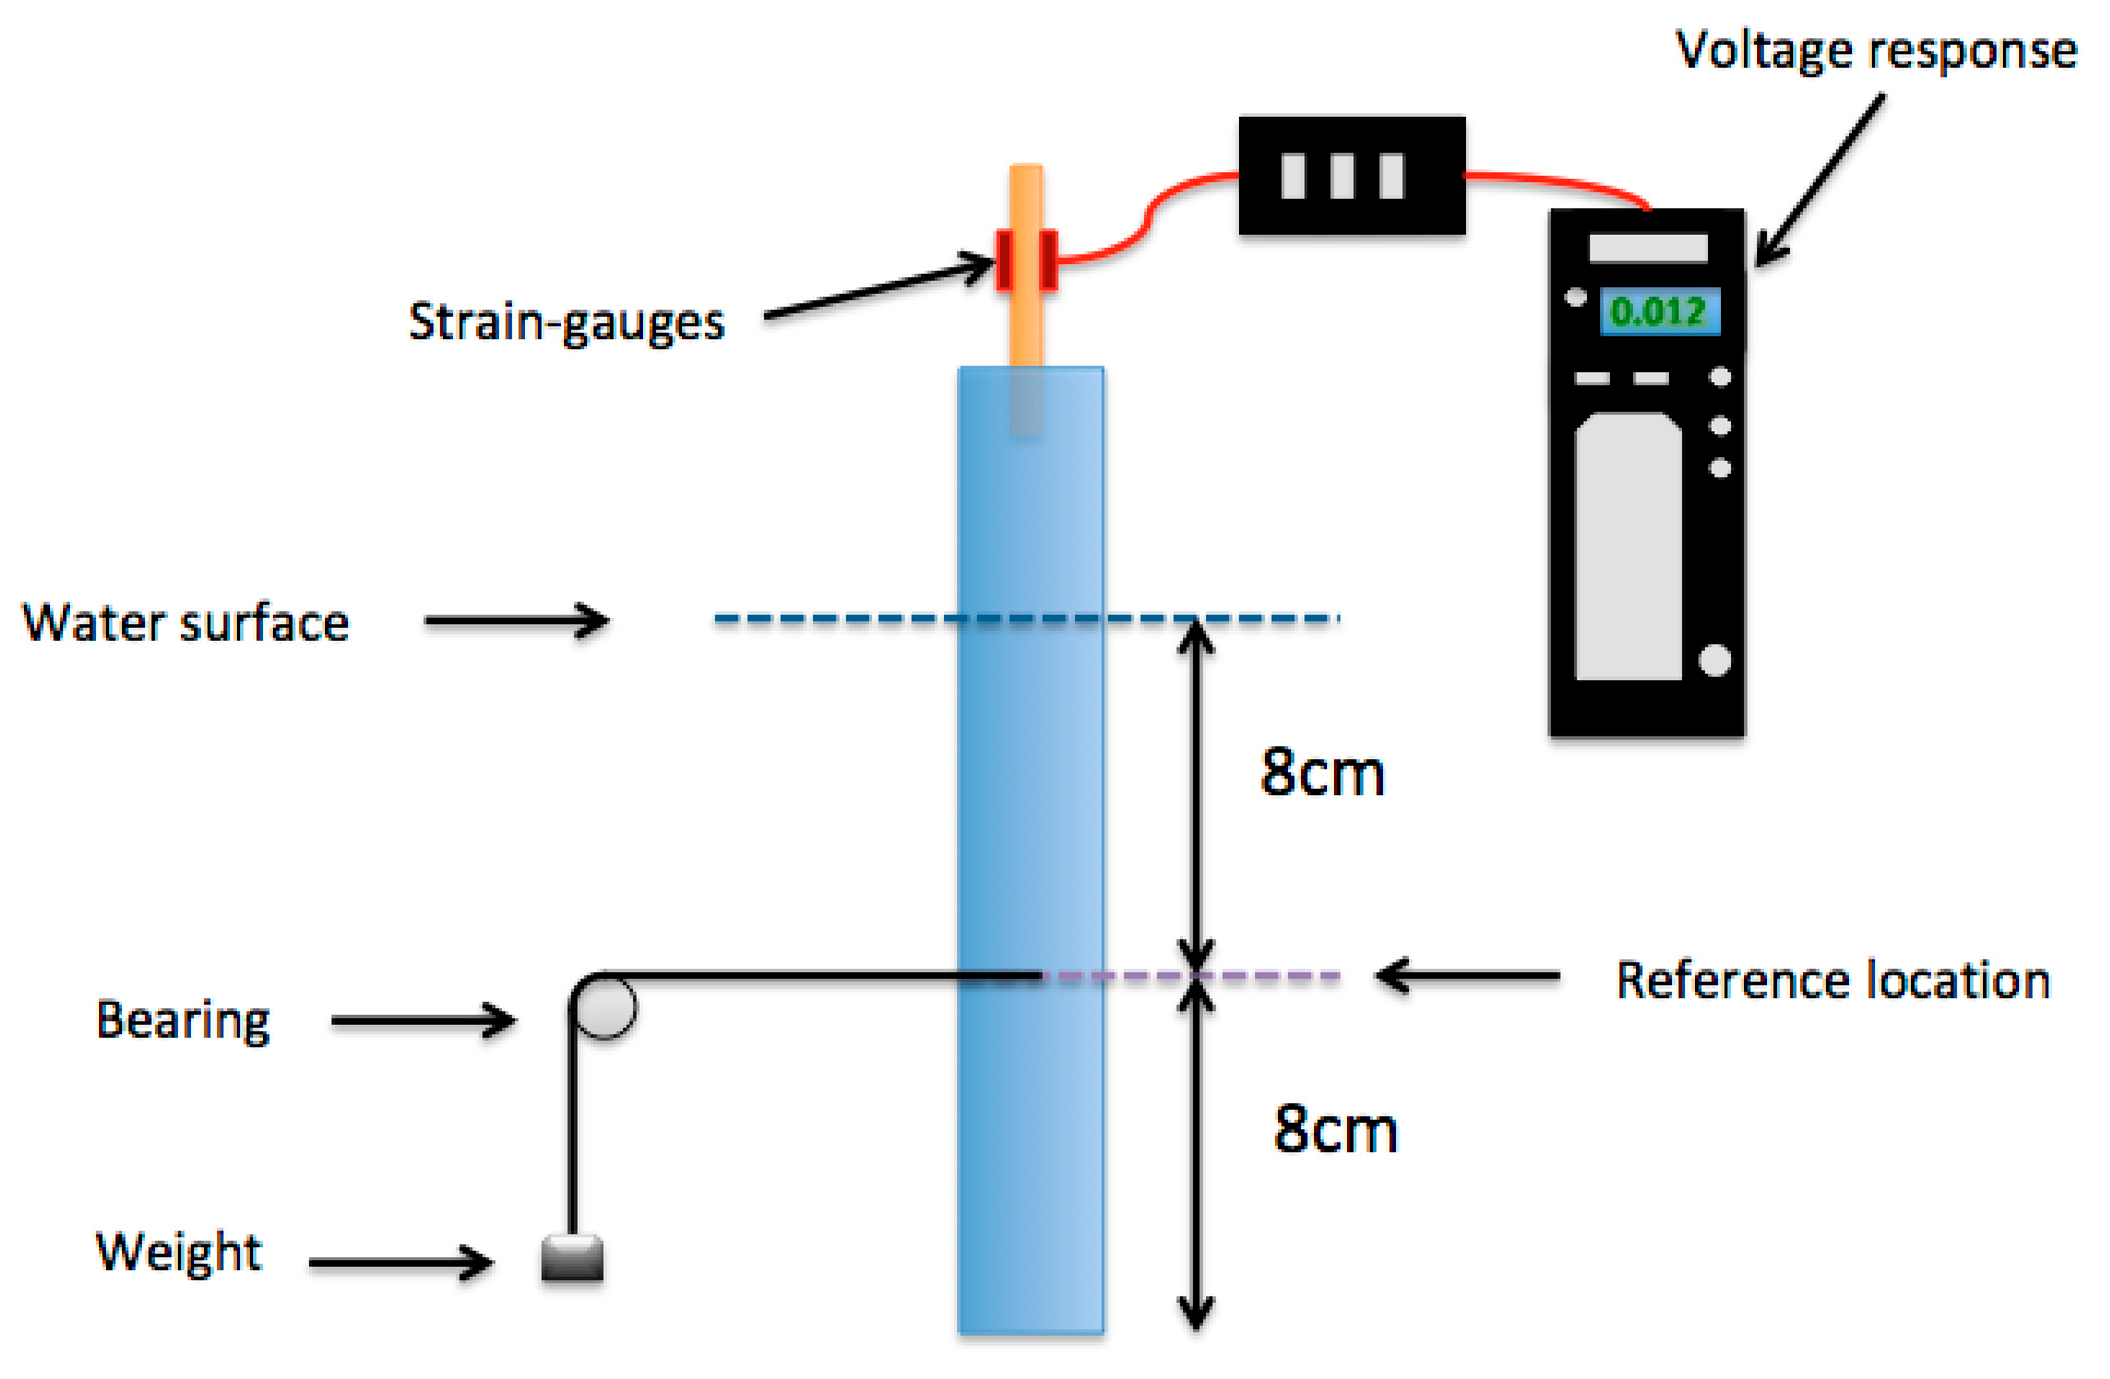
This process aimed to determine the correlation between the voltage read and the actual force applied on the wing. To do so, the wing was fixed vertically after setting it to zero. A thin string was attached at the reference location in the direction of the maximum response, offset by 90° from the zero response. The string was passed through a bearing to transform the horizontal force into a vertical one.
Weights from 1 g to 100 g were hung sequentially, and the voltage response was read for each weight. The procedure is described in Figure 12. Multiplied by the gravity constant g = 9.81 m/s2, linear regression was achieved. A correlation equation of Voltage [V] ⟶ a·Force [N] + b was then solved. Logically, b should be equal to zero. Finally, the procedure is conducted for both pairs of strain gauges. Because the lengths and the fixation setups of the circular and elliptical cylinders differ from the flat plate model, 2 different calibrations were performed.
The Voltage/Force correlations of the cylinder and the flat plate models for the first pair and second pair of strain gauges are summarized in Table 2. Note that the y-intercepts remain small compared to the slope. In comparison with the disturbances, we can neglect them and assume that they are equal to zero.

2.4.2. Lift and Drag Computation

Now that filtered data can be obtained and the correlation between the voltage output and the actual force applied is known, we can proceed to the actual lift and drag computation [18,19]. The two unknowns, drag and lift, require two equations, which is why two pairs of strain gauges are used. Every pair of strain gauges responds to two forces, the lift and the drag. Detailed descriptions of lift and drag calculations can be found in the experimental work of Samuel Verboomen [20].

2.4.3. Phase-Averaged Lift and Section Lift Coefficient

Using the lift over time previously found, the phase-averaged lift per unit span can be calculated as
l a v = 1 b 0 p L t d t
where b = 0.16 m is the wingspan (more specifically, the length of the wing soaked in water). From there, as a characteristic of the particular shape of the wing section, we can compute the section lift coefficient:
c l = 2 l a v ρ w a t e r V x m a x 2 t w
where tw is the thickness of the wing. For the flat plate model, tw = 0.003 m, which represents the thickness of the plate. For the elliptical cylinder model, tw = 0.015 m, and it represents the small axis of the elliptical section. Finally, for the circular cylinder model, tw = C = 0.03 m.

2.4.4. Method Validation

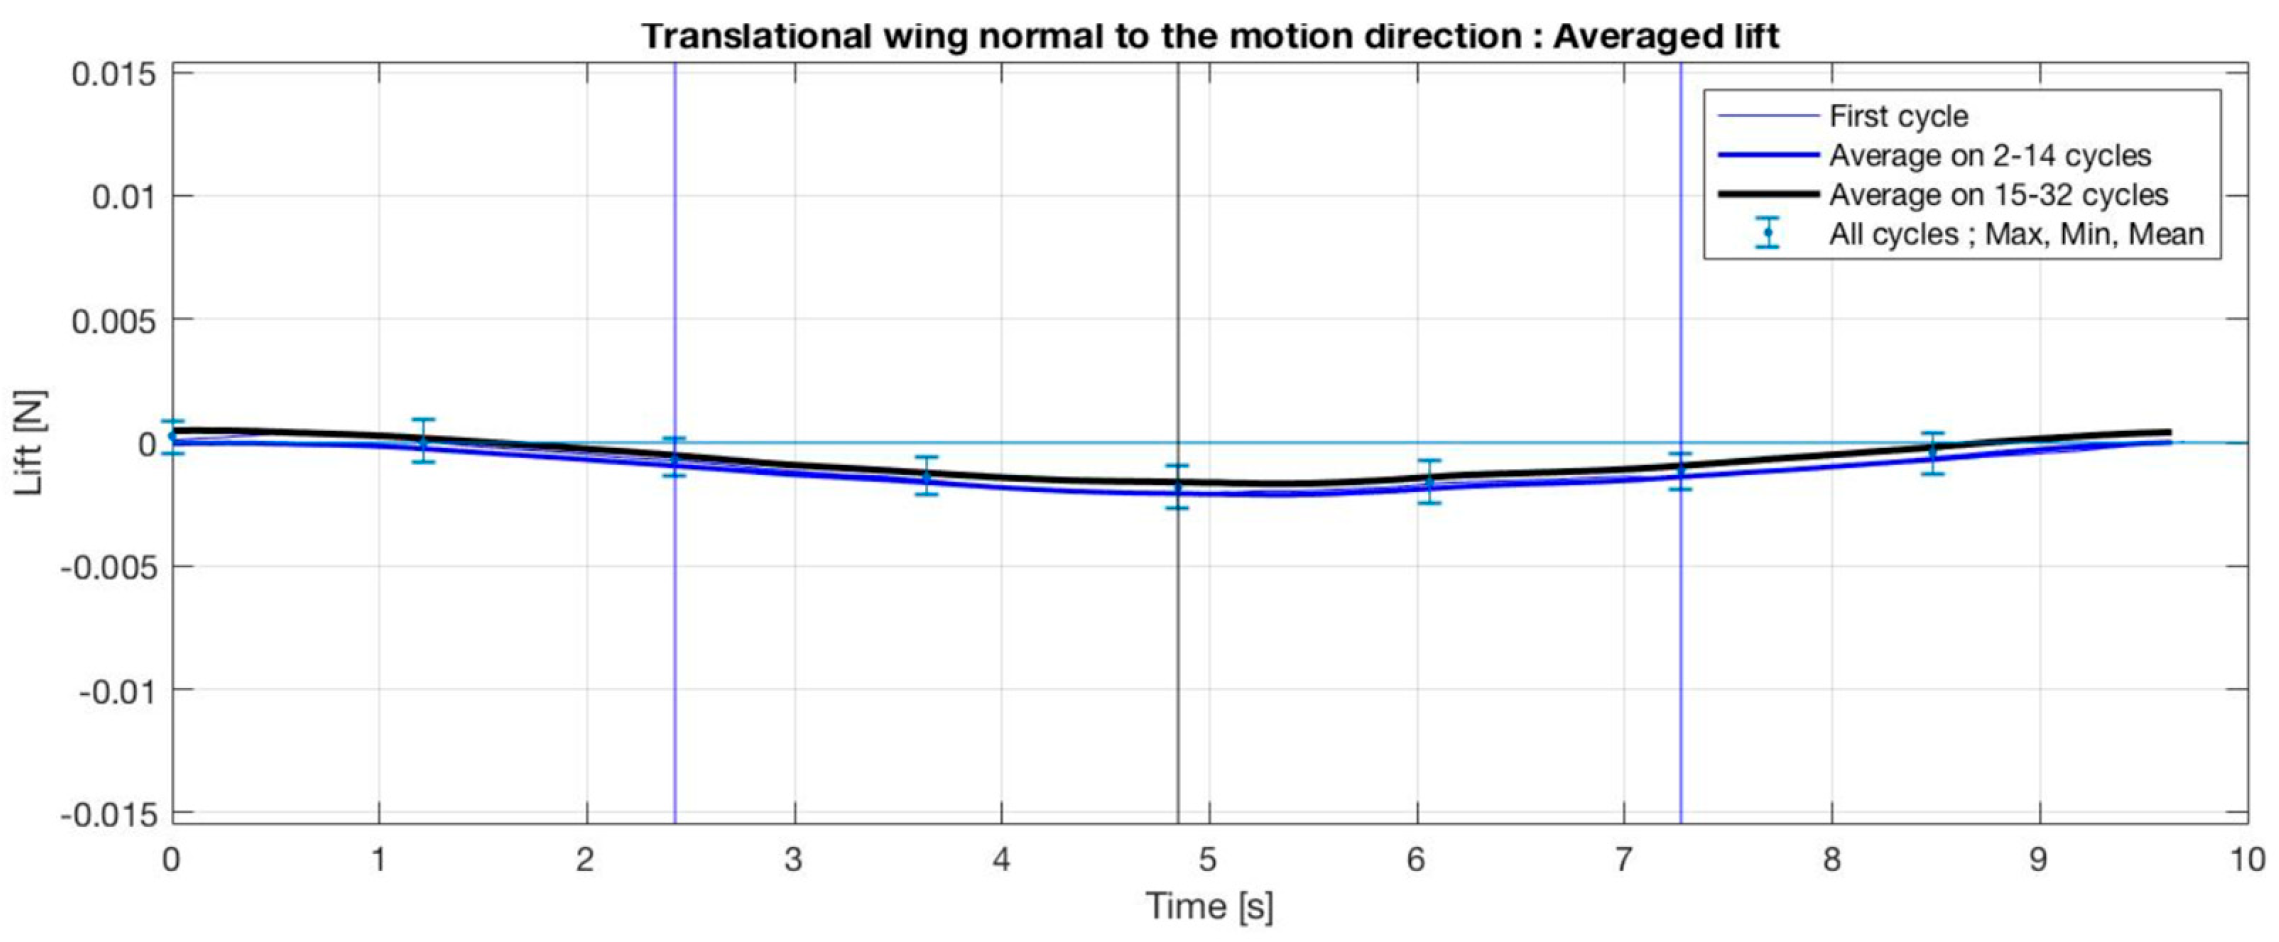
To validate our method, first, a simple experiment that should yield straightforward results was conducted. The response of a simply translating wing to the forces was measured. Using the flat plate model with its section in the typical motion direction (θ (0) = θ (t) = 0), a lift equal to zero is expected, because no rotation is induced and the angle of attack remains equal to zero. Furthermore, positive drag during the upstroke and negative drag during the downstroke, with mid-stroke V x = V x m a x , is also expected.
The results of this experiment are shown in Figure 13. The results are as expected, with good regularity over the 32 cycles. Note that the drag curve appears to be slightly shifted, with a non-zero value at the end of each stroke and a maximum value prior to mid-stroke. This is due to the unsteady nature of the motion, including the wake capture effect, which still applies force to the wing even when it is at rest.

2.5. PIV Measurement and Flow Structure Analysis

2.5.1. Method Description

To visualize the surrounding flow structure, we used the particle image velocimetry (PIV) method by injecting particles inside a fluid (which was the water inside the tank in our case) and illuminating them with a laser sheet. With this setup, only a two-dimensional analysis can be achieved. However, by shooting the laser at the reference location (see Figure 6b), the resulting analysis will be coherent with our previous direct force measurements.
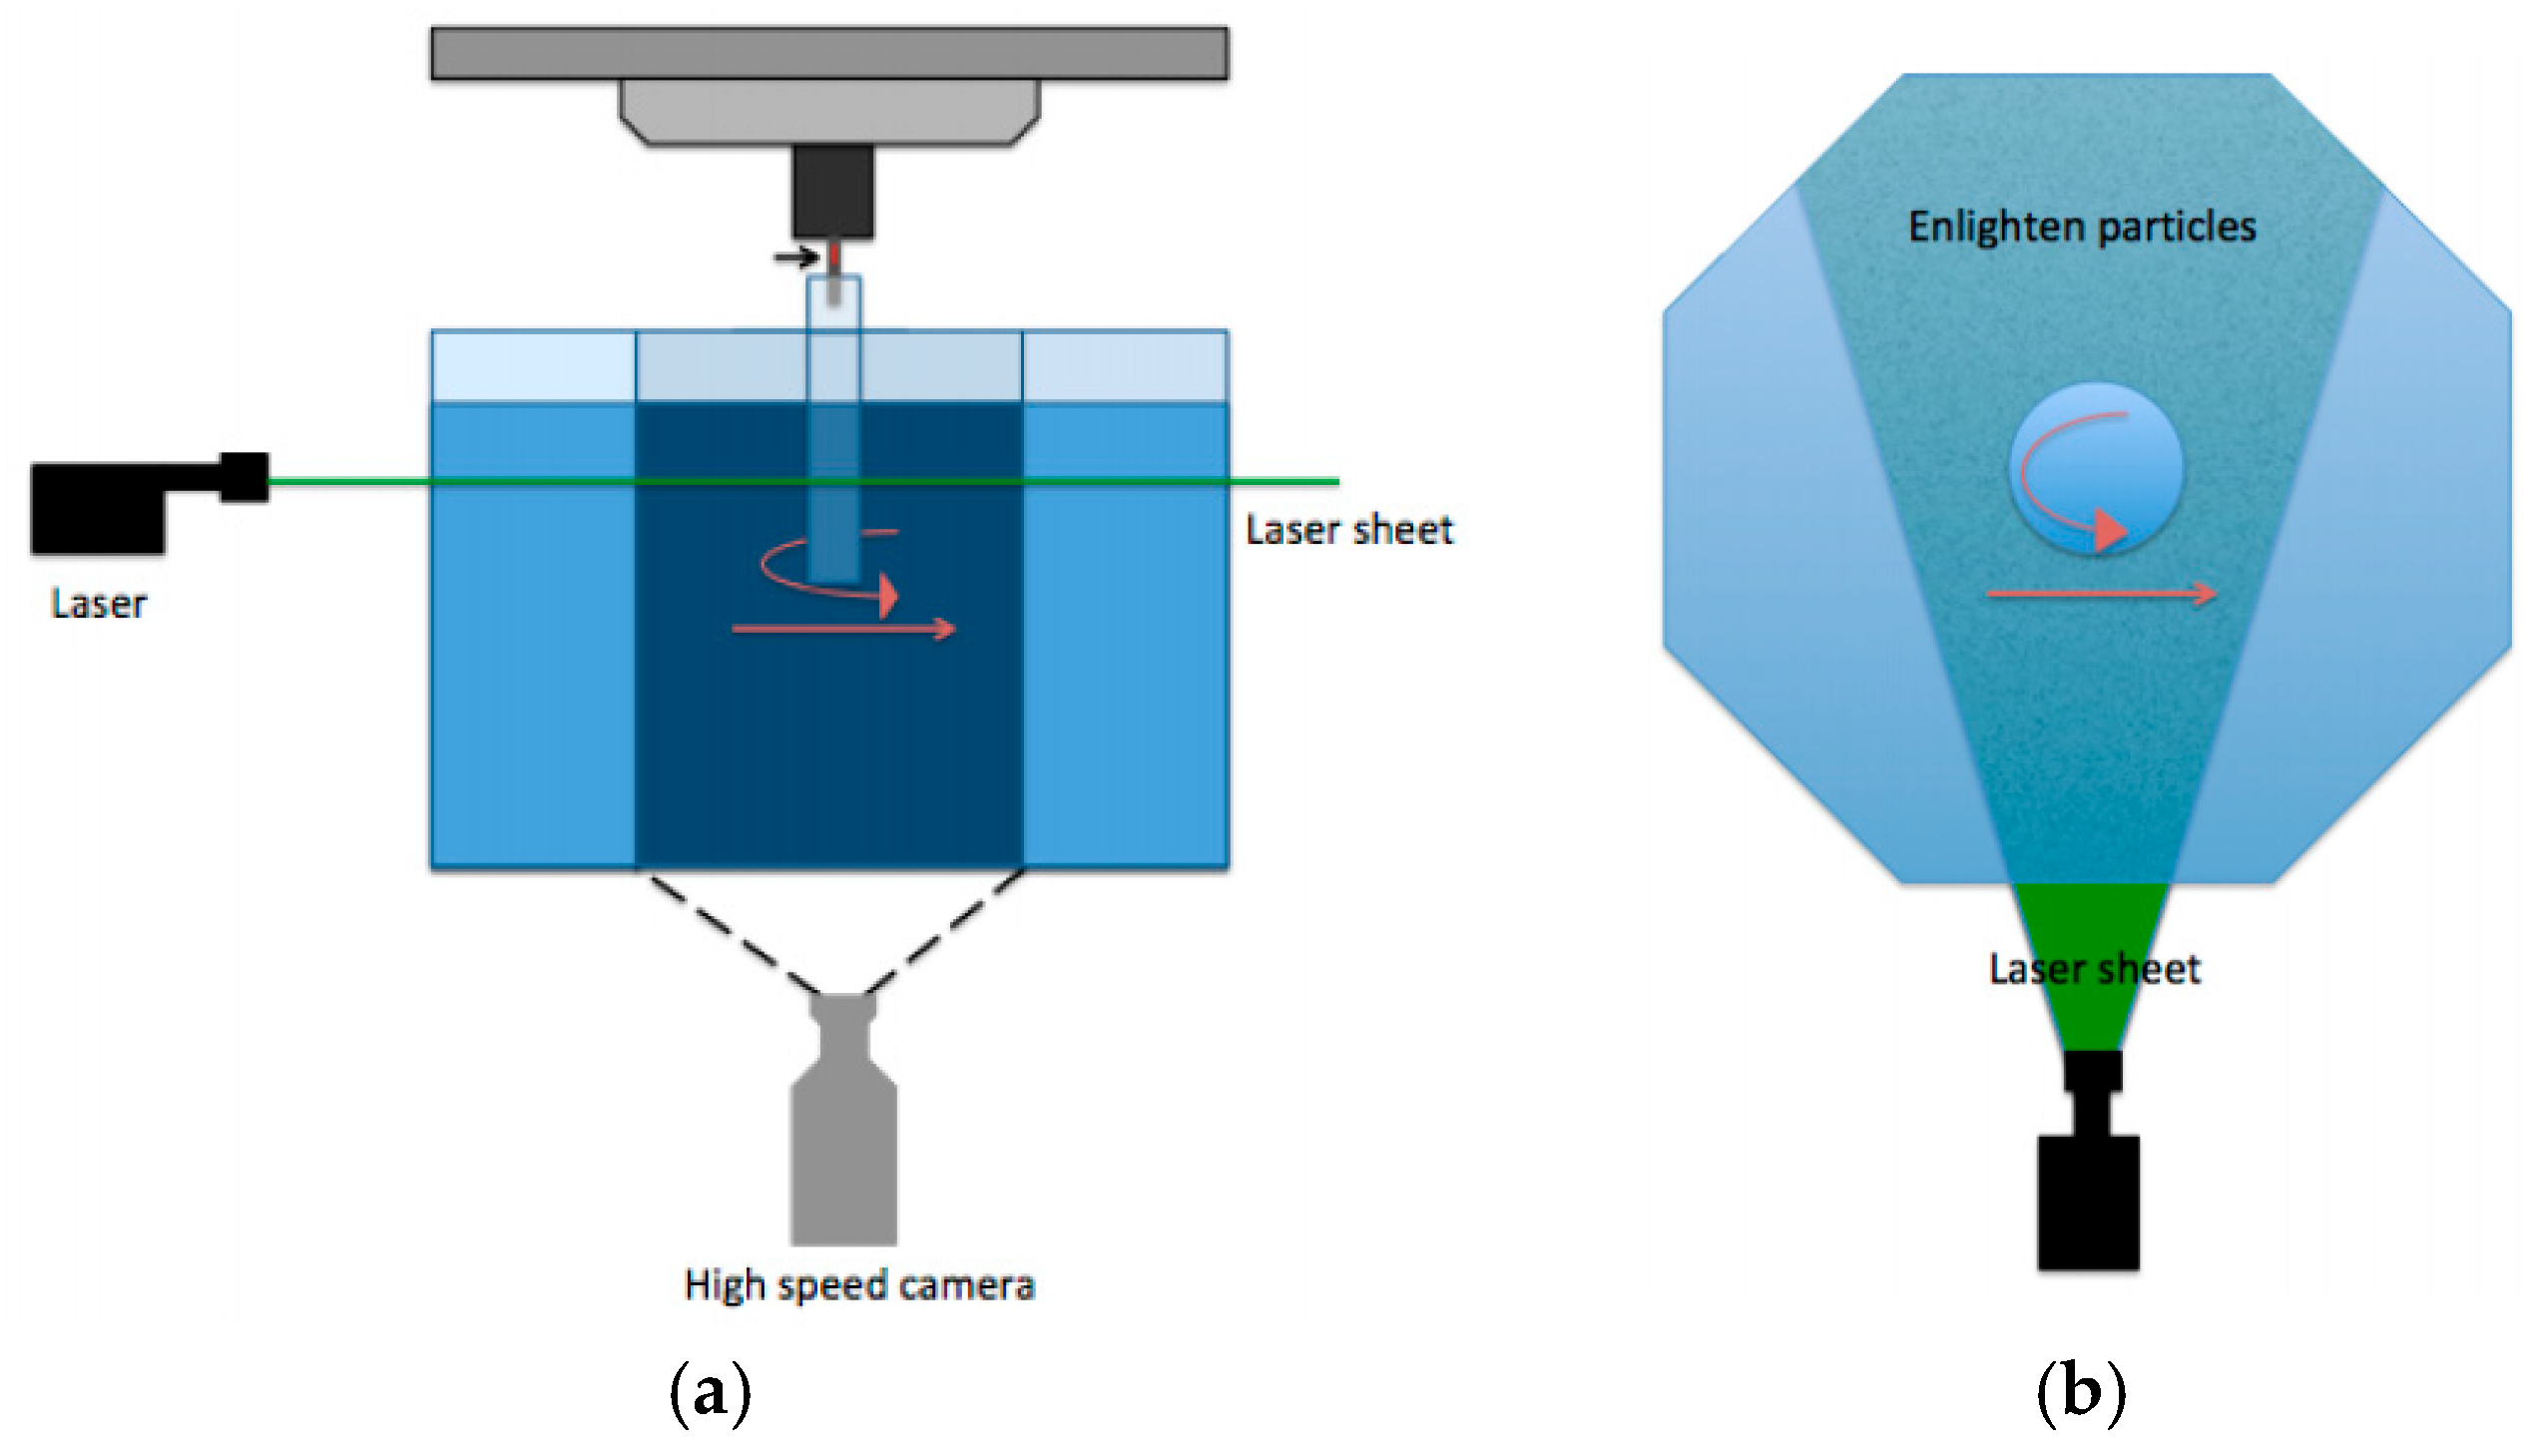
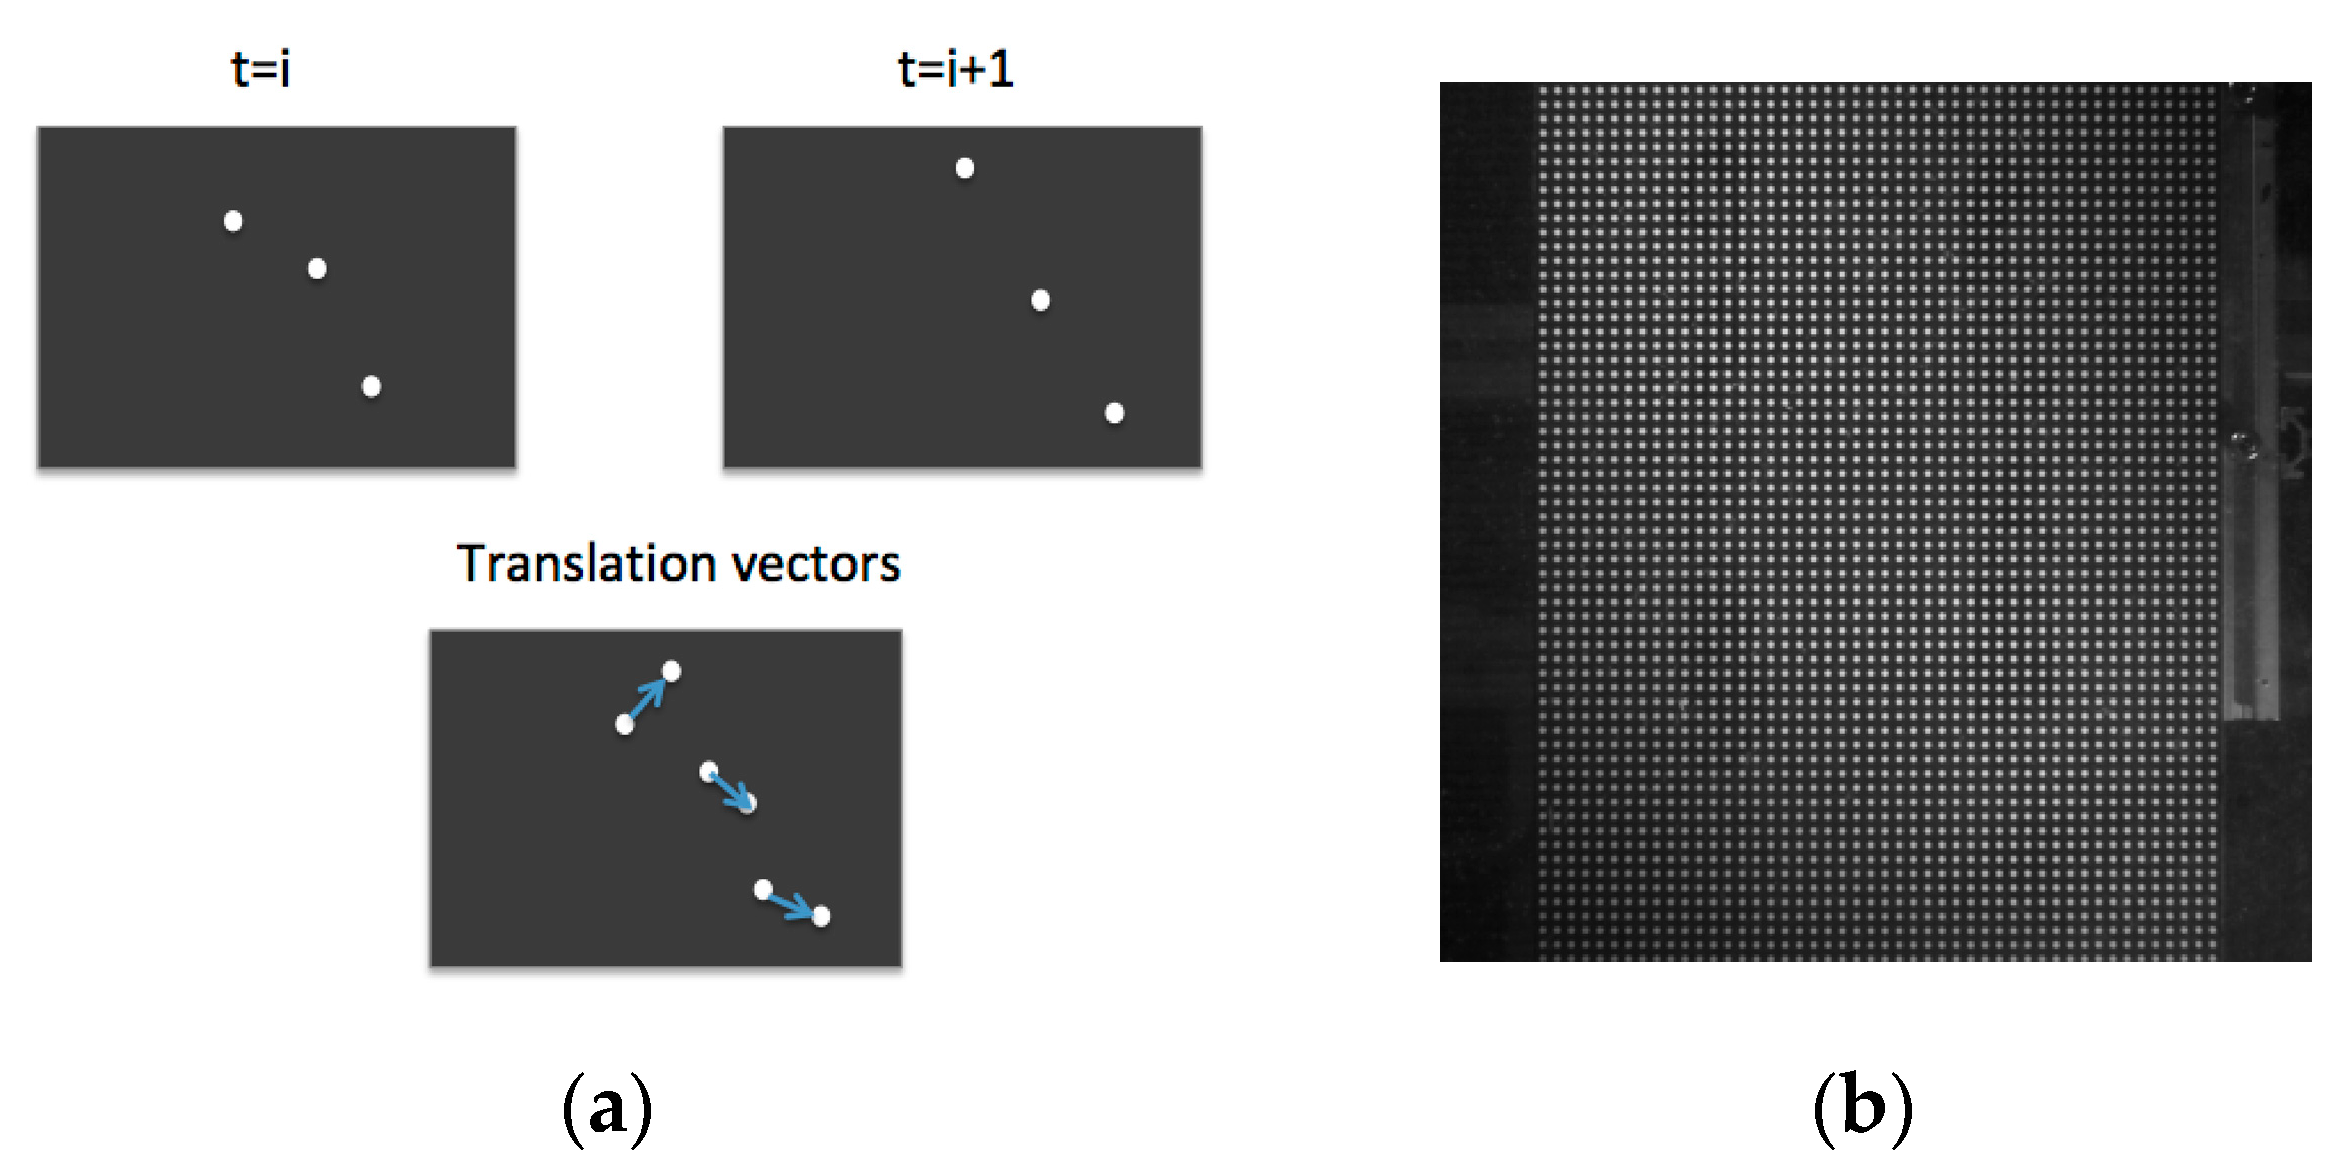
Using a high-speed camera, we can track the particles’ position at each instant t. The PIV equipment’s specifications are listed in Table 3. By taking a small time step, the velocity vector can be found for every particle throughout the duration of the experiment to obtain the total velocity field. The side view and the upper view of the PIV setup are shown in Figure 14a,b. The tracking process is schematized in Figure 15a. Compared to other methods, such as laser Doppler velocimetry or hot-wire anemometry, this allows us to obtain the instantaneous velocity for many. Moreover, it is a non-intrusive method, and it does not disturb the flow around the wing [21].
Finally, a calibration method was needed. Because of the angular distortion of the camera, it was not entirely correct to define a certain number of pixels as being equal to a certain value in millimeters. Therefore, a picture of the calibration board, shown in Figure 15b, was taken to extrapolate the real positions of the particles according to their location, defined in pixels, on the recorded frame. The last 18 cycles were recorded such that a fully developed flow could be validated. For the three-wing models, only one half cycle was analyzed, as all of the models were symmetrically similar. As such, a phase average was unnecessary.

2.5.2. Vorticity ω-Criterion

Now that our velocity field v = ui + vj + wk at every instant t is acquired, we can analyze the flow structure to better understand where lift generation comes from. To do so, we can observe the vorticity ω, defined as the curl (rotational) of the velocity in 2D:
  ω = ×   v = δ v δ x δ u δ y k
This vorticity indicates the strength of the shear or the vortical flow structure.

2.5.3. Q-Criterion

A more efficient means of acquiring vortex cores is the Q-criterion [22], which represents the contribution of the shearing component over the rotation component. If S is the shearing tensor and Ω is the rotation tensor, Q is defined as S 2 Ω 2 . For 2D structures, Q is defined as follows:
Q = 1 2 δ u 2 δ x + δ v 2 δ y + δ u δ y δ v δ x
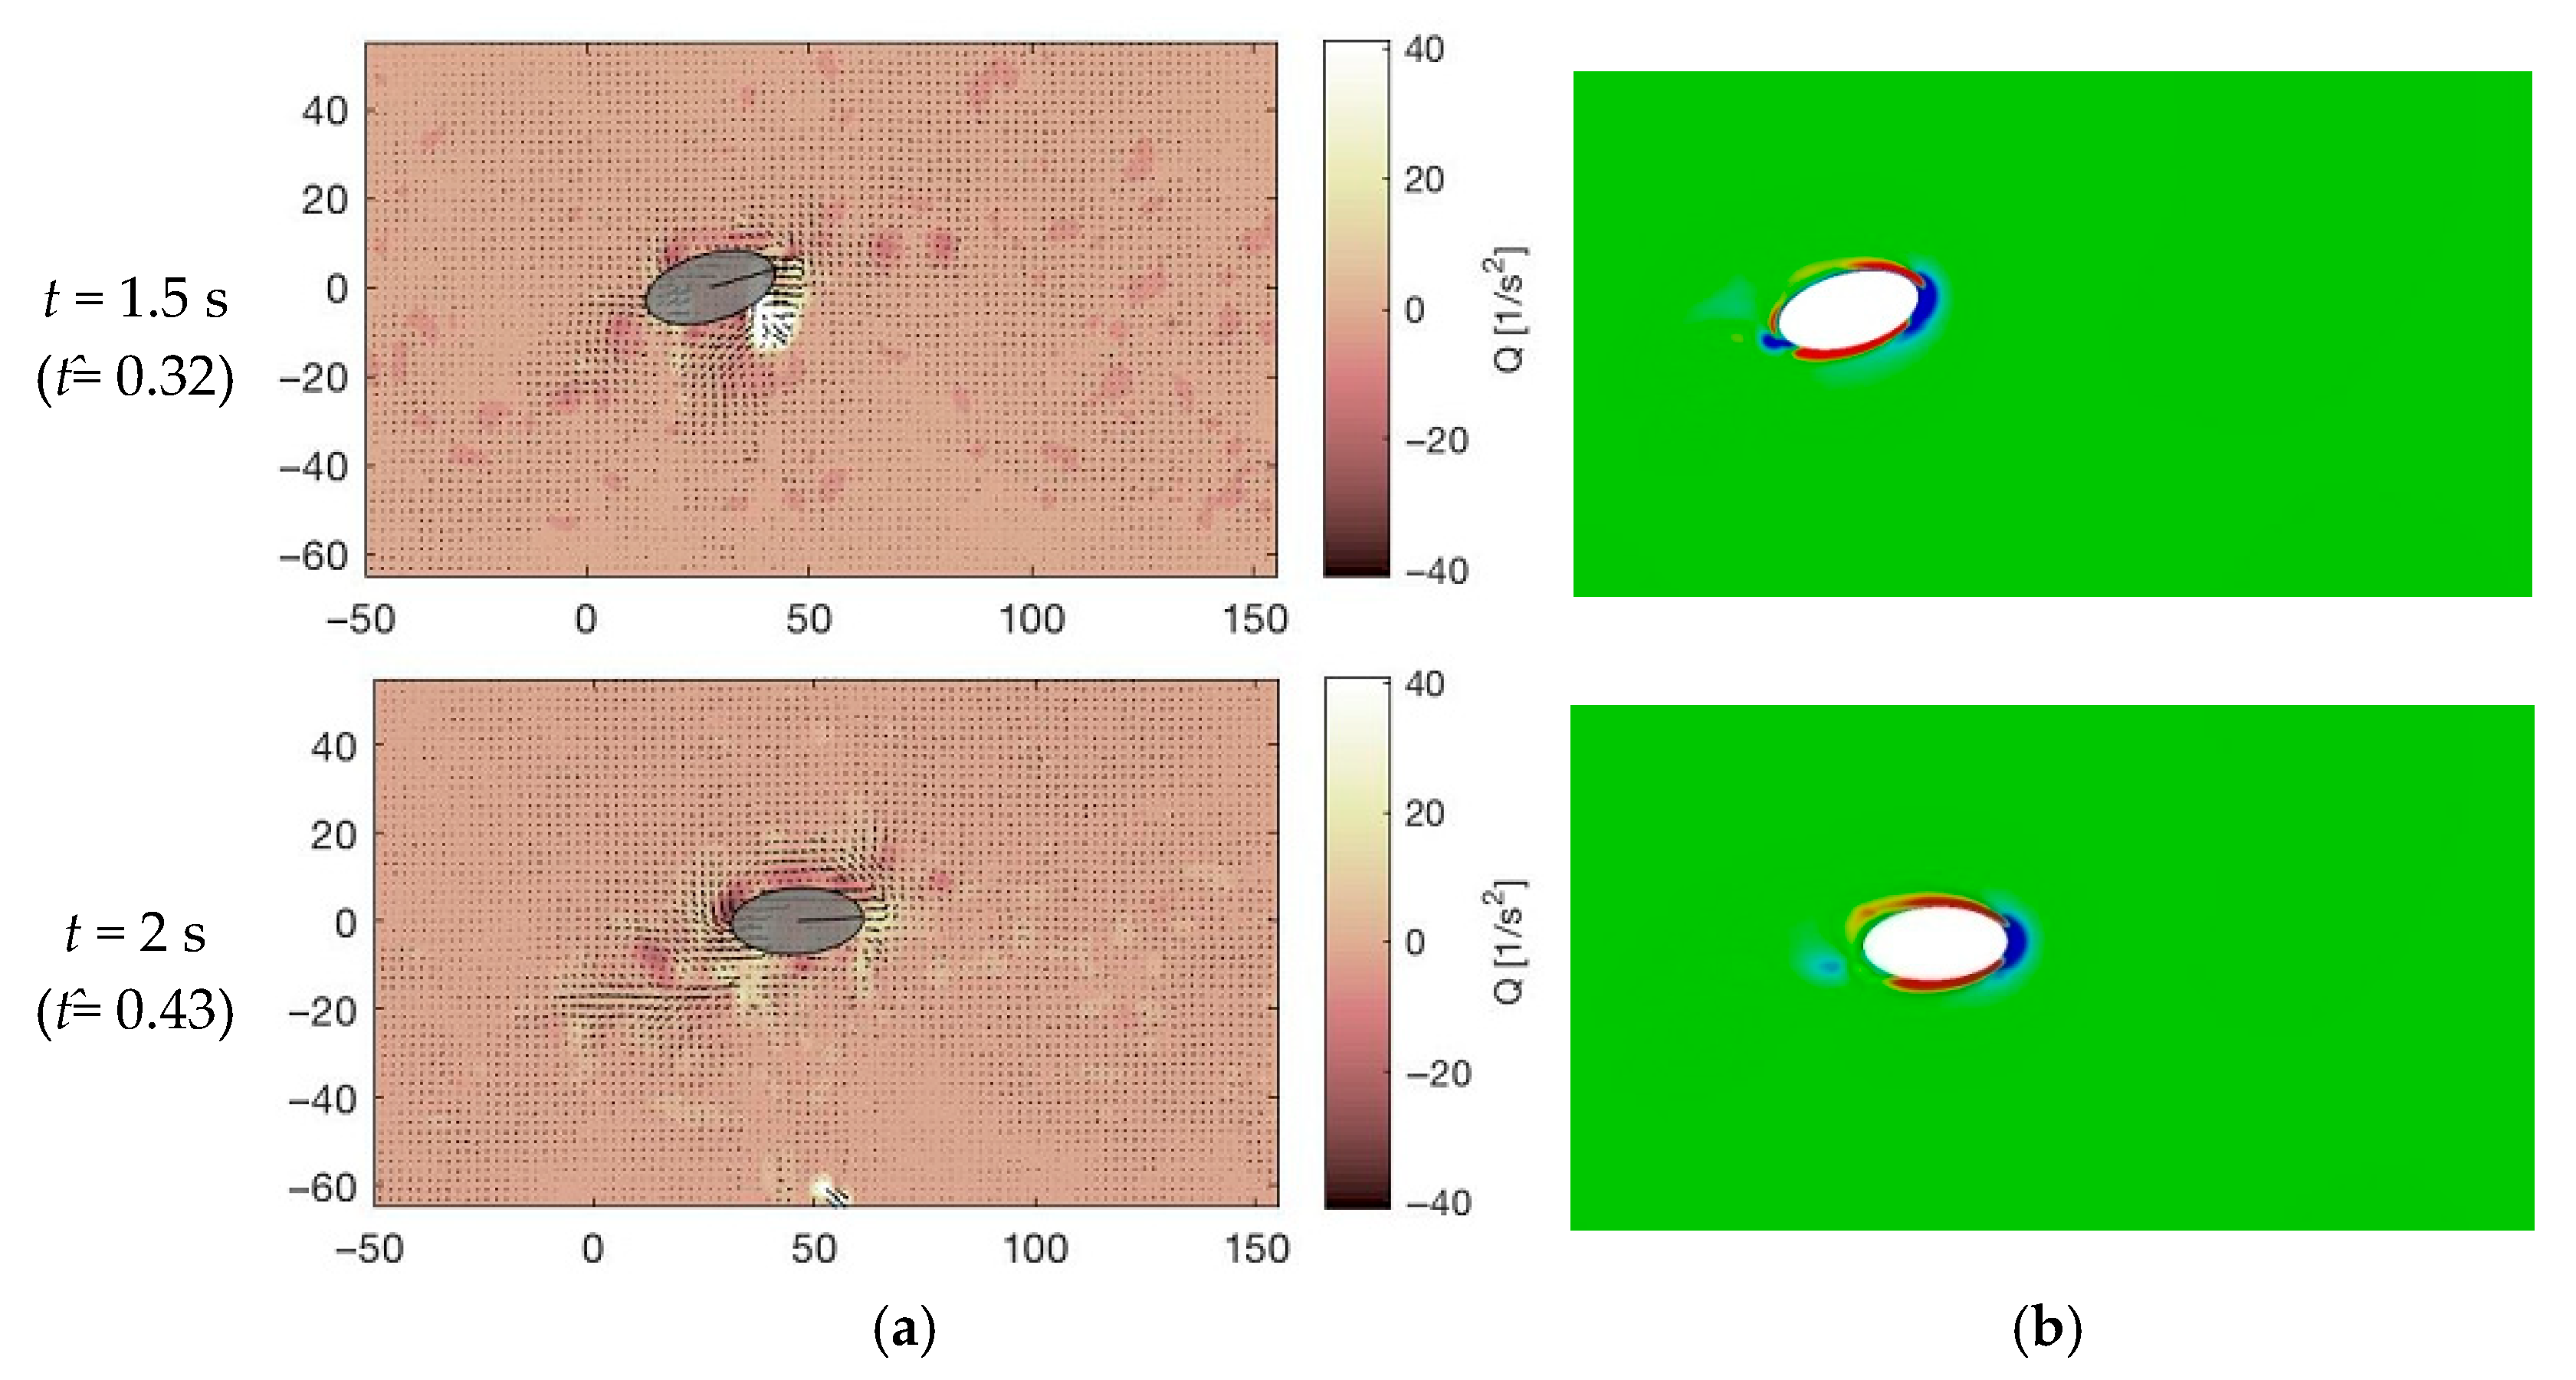
Therefore, according to the definition, vortices are created when Q is negative and when the rotation is more important than the shear component. Nonetheless, a good threshold must be found to clearly visualize the vortices’ cores.

2.5.4. Lift Computation Using Kutta–Joukowski Theorem

Whether the Magnus effect or the Kramer effect occurs, lift is produced due to the generated traffic. In the case of the Magnus effect, the difference in relative speed creates traffic. For the Kramer effect (as well as the creation of the LEV), this circulation is generated upon re-establishment of the Kutta–Joukowski condition. Thus, we applied the Kutta–Joukowski theorem to our PIV results to estimate the lift produced. This “quasi-steady” does not depend on its evolution over time. Other derived methods that consider the time dependency can be used a second time, as explained by Stalnov et al. [23] and Flavio Noca [24]. Hence, comparisons between these results and measurements of the direct forces can be made. In addition, because the theory applies to stable-state irrotational flow, applying these equations to the flow around the flapping motion rests on significant assumptions. The Kutta–Joukowski theorem gives the relationship between lift and circulation on a body moving at constant speed in a real fluid with some constant density.
L/b = −ρUΓ = −ρwater Vx Γ,
where ρwater = 998.23 kg/m3 is the water density at 20 °C, Vx is the translational velocity of the wing, b = 0.16 m is the wingspan (more specifically, the length of the wing soaked in water), and the circulation around the wing is defined as
Γ = s ω d s ,
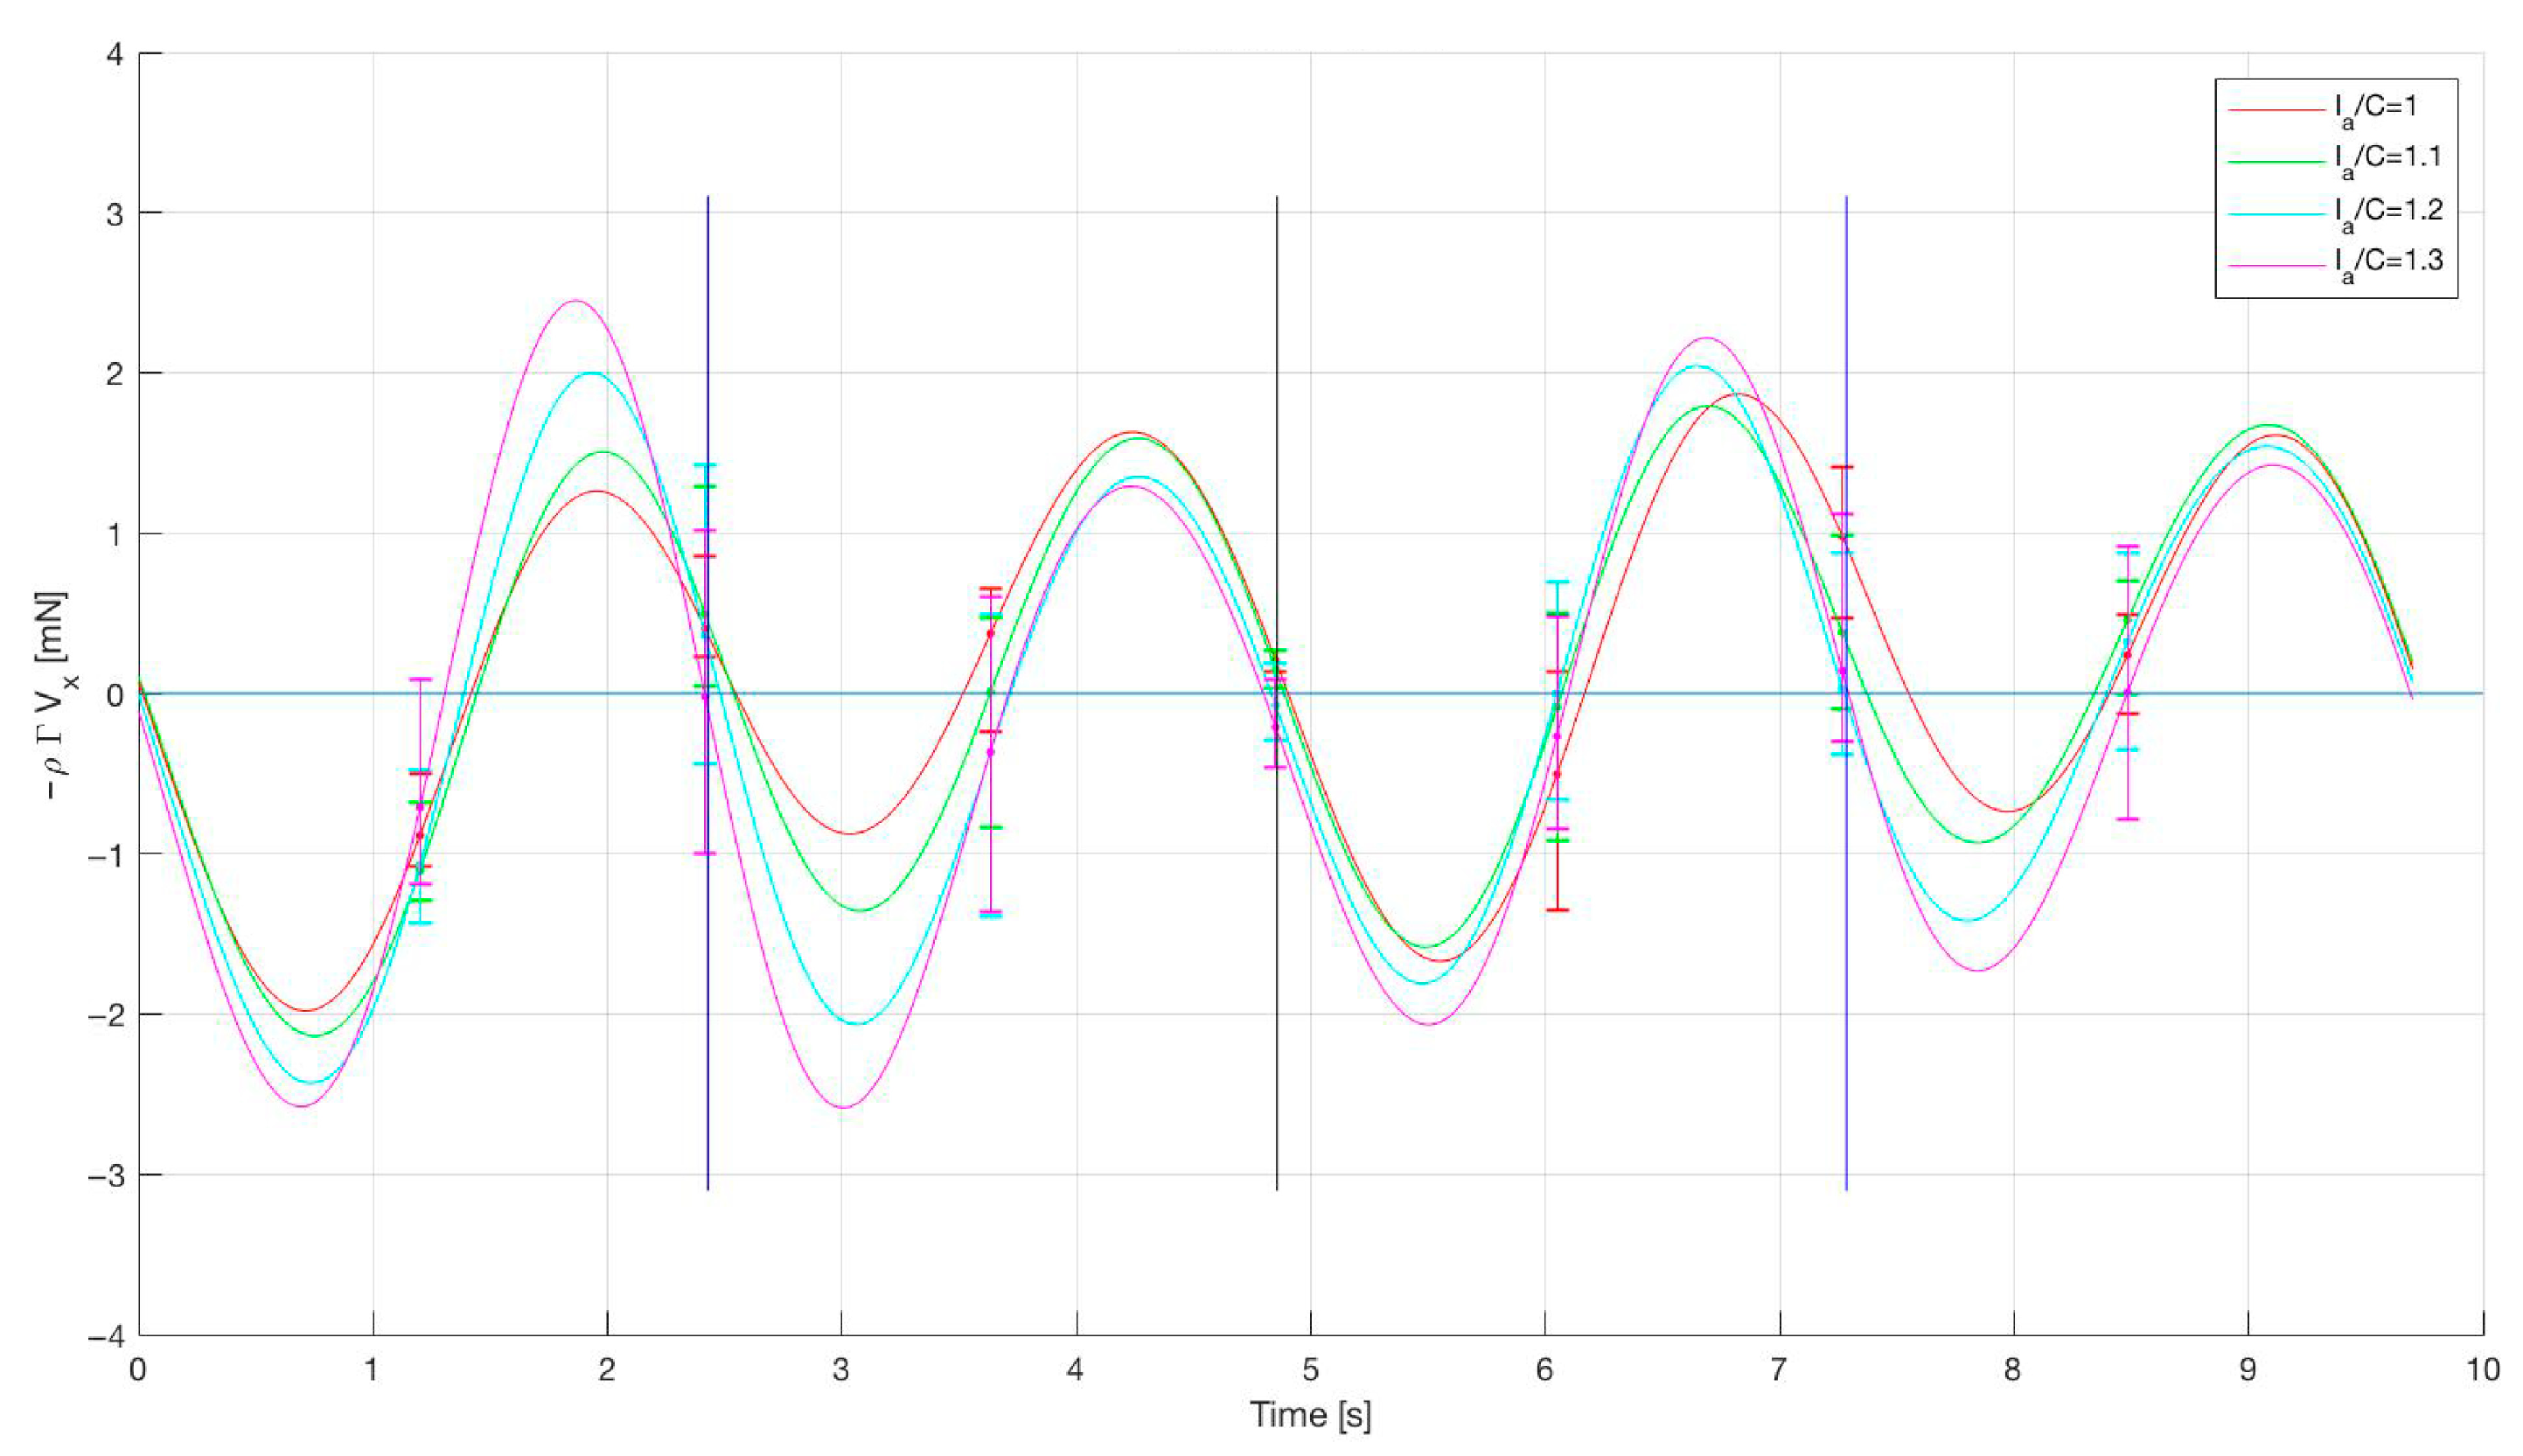
where ω is the previously defined vorticity. The control area for integration is a key parameter for the previously found lift. Although other interesting shapes might be considered [25], a simple square around the wing is preferred. Finally, the length of a side, denoted as la, must be defined carefully. Results for la/C = 1, 1.1, 1.2, and 1.3 will be displayed, where C is the chord length of the wing, 30 mm. The phase average of the last 18 cycles was computed to obtain better precision. Finally, a low-pass filter was applied to obtain smoother results.

3. Computation

Flow around a flapping wing with a Reynolds number of 1200 was measured for all 3 models to obtain reference data to validate the experimental results. Open-source CFD software, OpenFOAM, with a version of foam-extend-3.2, was used for numerical simulations. A solver “icoDyMFoam,” based on the PISO method, was used for velocity–pressure coupling. Numerical schemes used for discretization are summarized in Table 4.
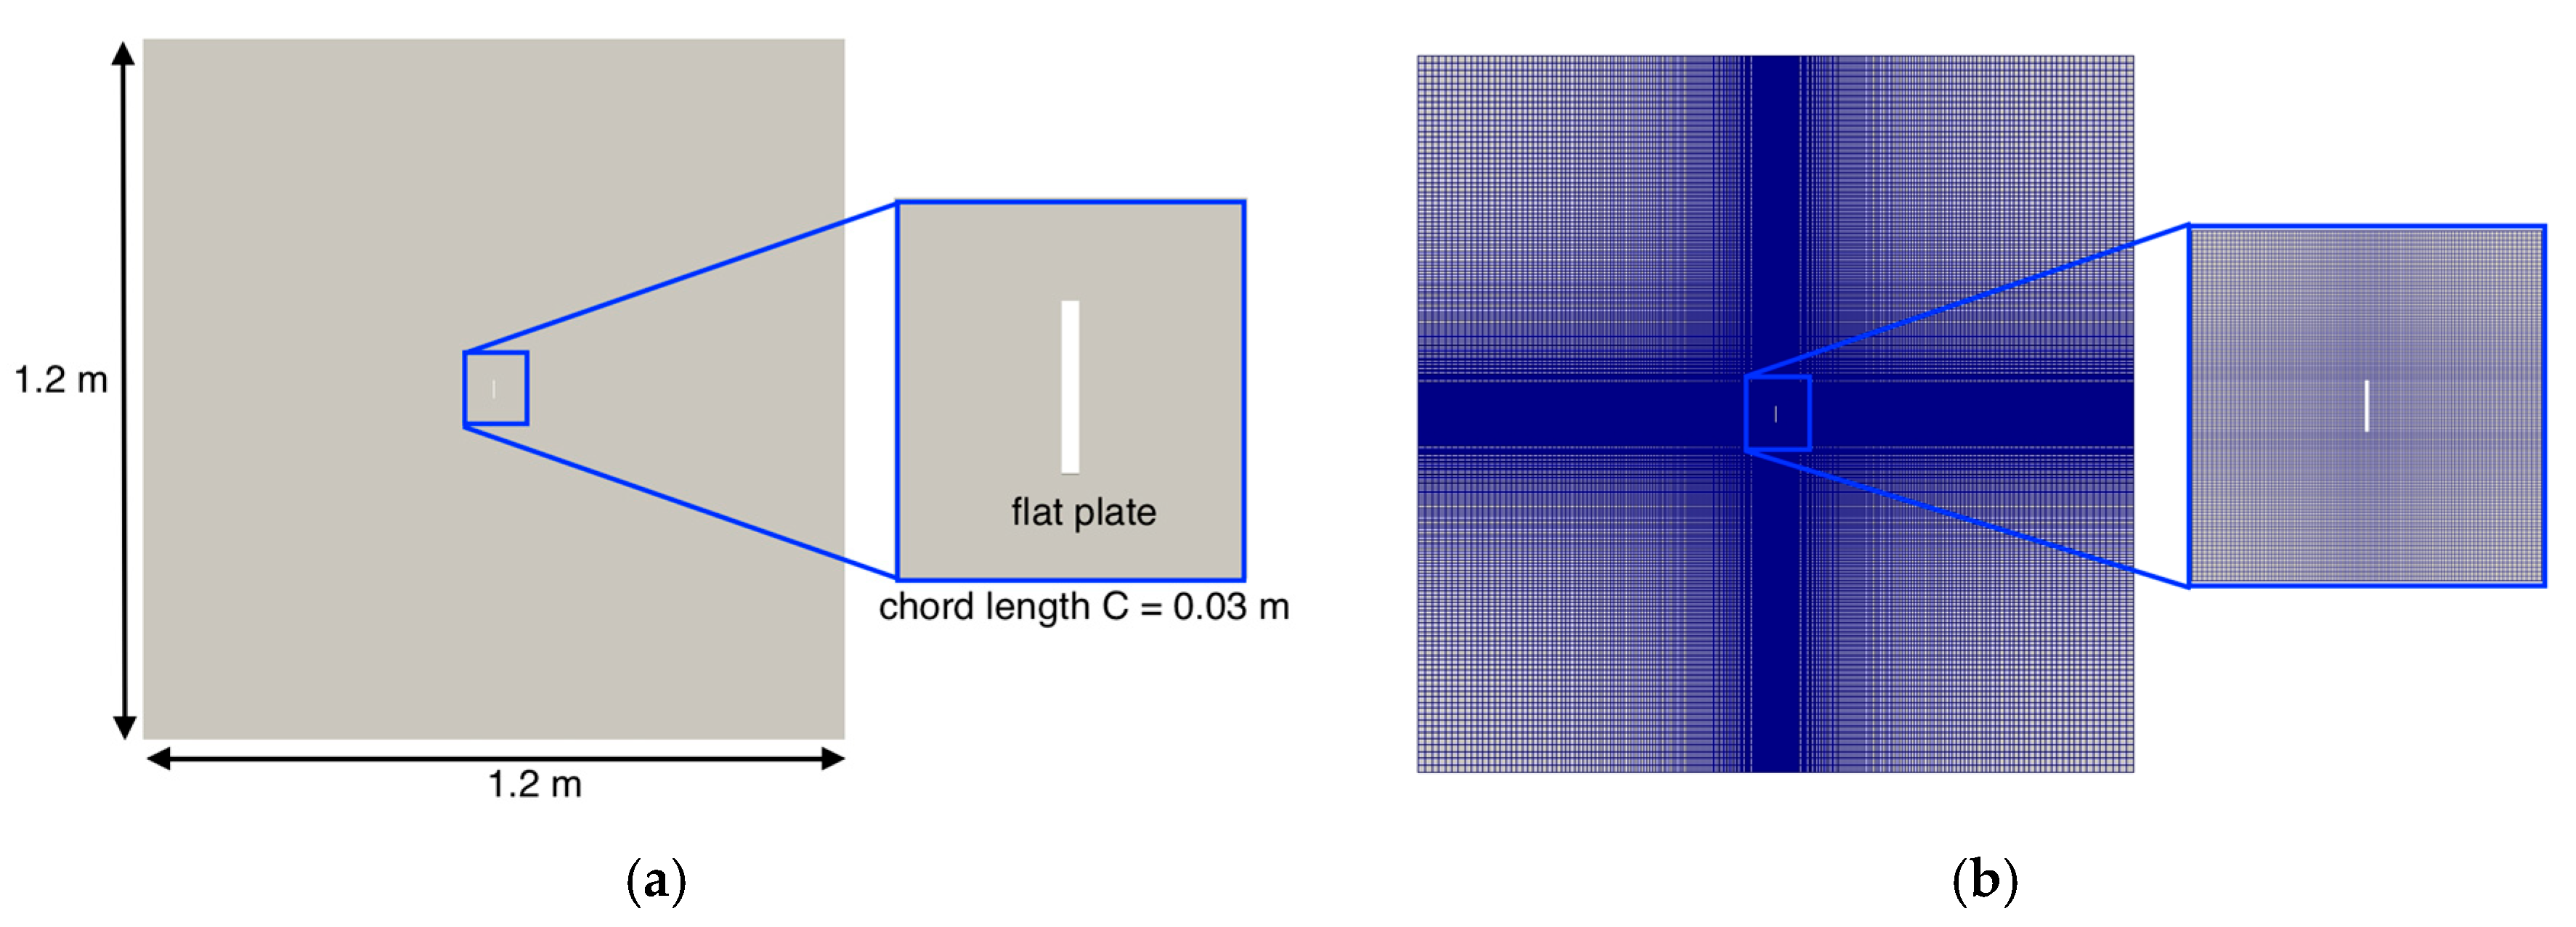
The 2D mesh had a square-shaped computational domain and consisted of approximately 0.7 million meshes concentrated around the wing. The domain size was −20 ≤ x/C ≤ 20 and −20 ≤ y/C ≤ 20 in the x and y directions. A schematic view of the two-dimensional computational domain for the flat plate model and the corresponding grid generation are shown in Figure 16a,b. The time step size was set to 0.01 s with a Courant number of 0.5 for all cases, and the same structured mesh types were used for simulations of all three models. The “zeroGradient” option was applied to both the velocity and the pressure on the side boundaries of the domain. For the boundary condition on the wing, the “movingWallVelocity” and “zeroGradient” conditions were applied to the velocity and the pressure, respectively. The rotational and translational motions of the wing were imposed using the “RBFMotionFunction” solver.
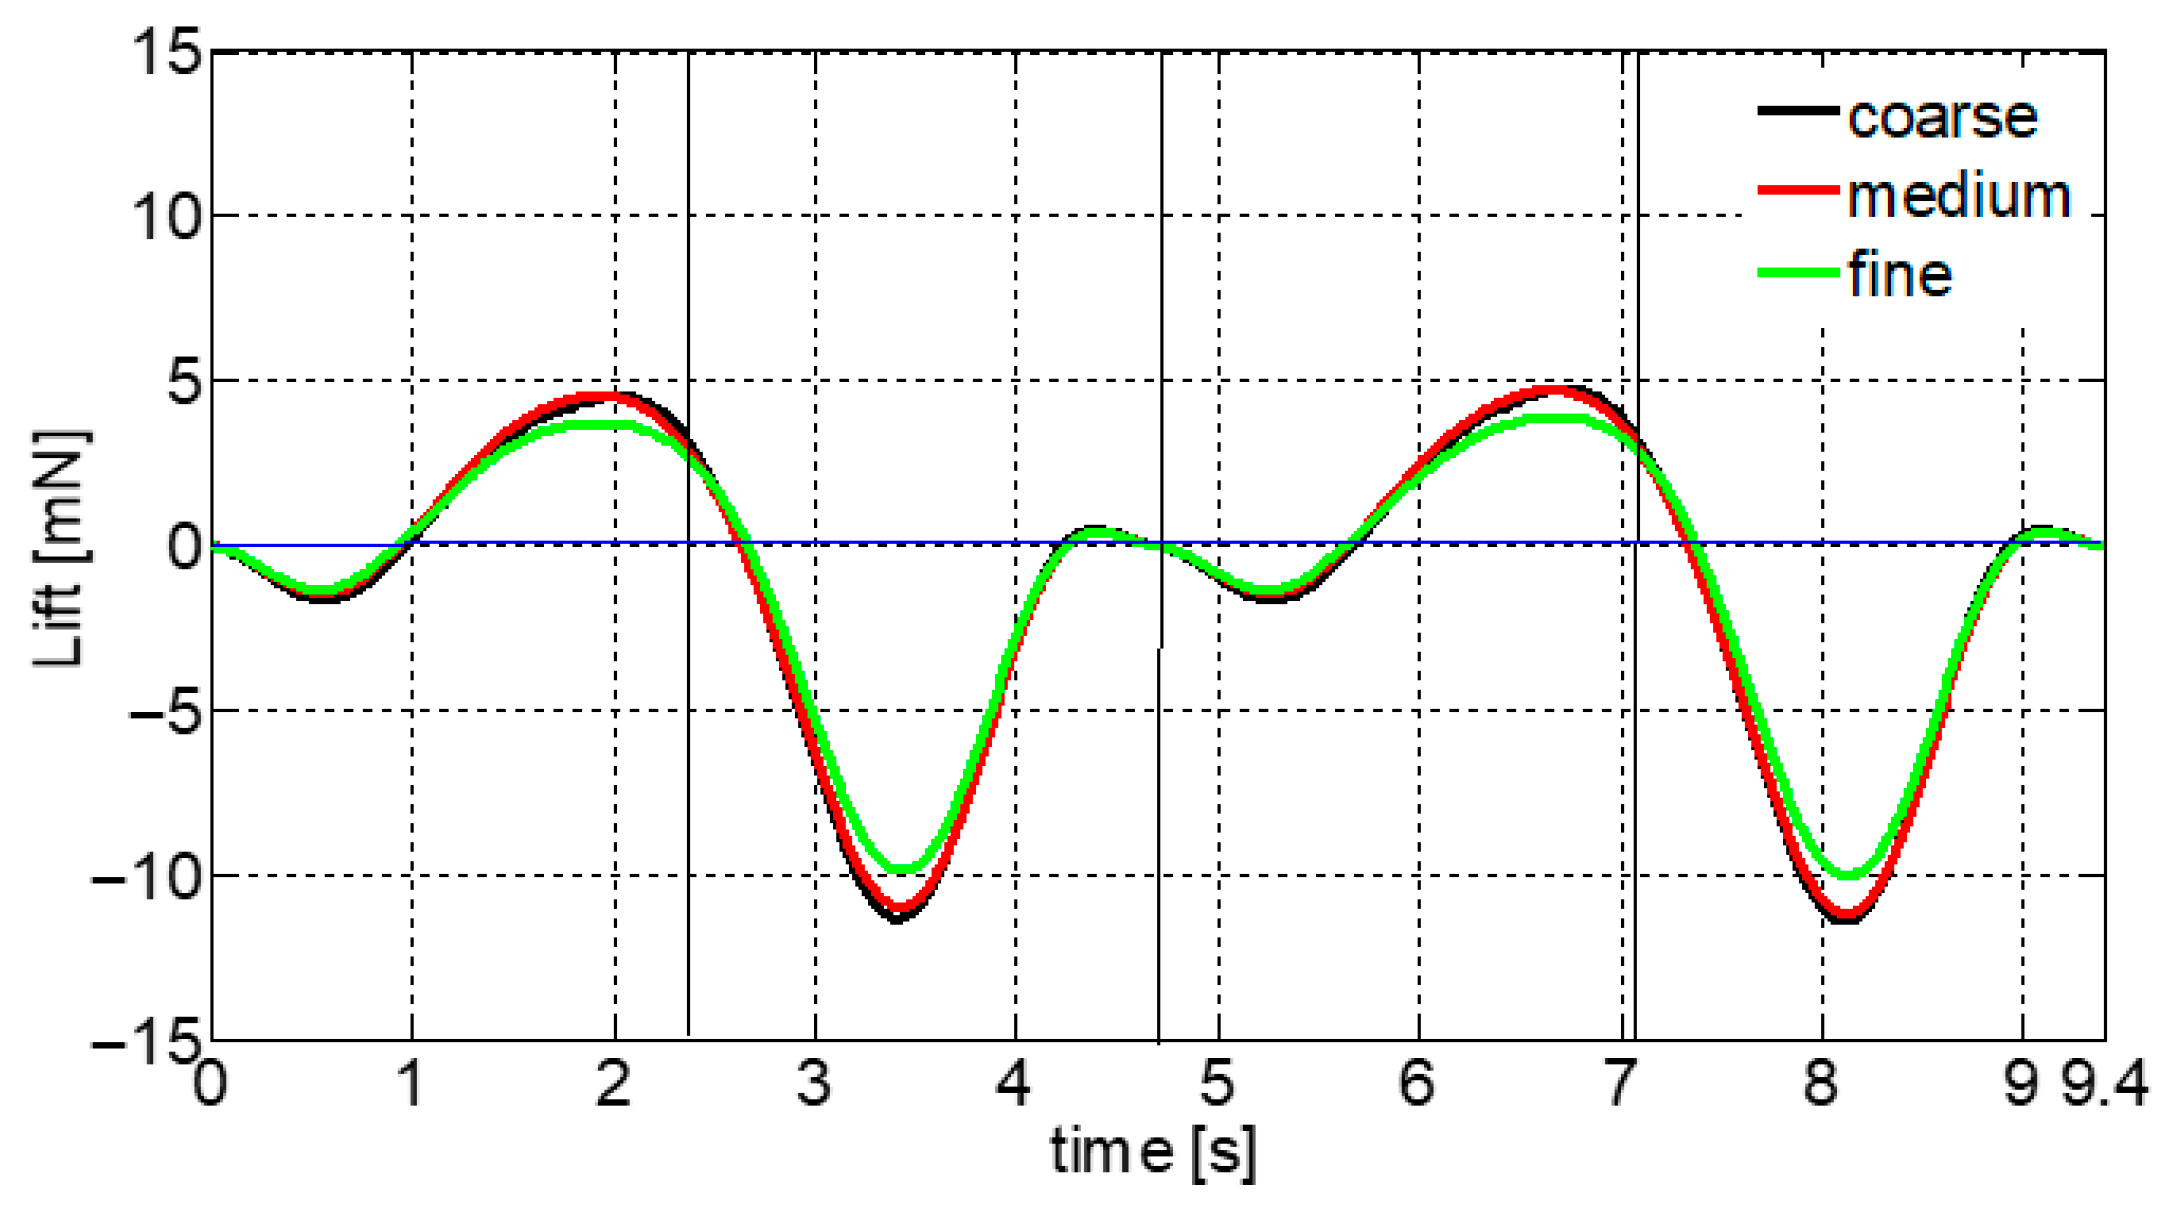
To select a suitable grid, computations were conducted on three different meshes: approximately 0.18, 0.36, and 0.7 million meshes. The impacts of grid size on the lift force generated by the flat plate model are shown in Figure 17. The periodic state was reached after the first four flapping cycles. The different grid sizes considered in the simulation of the flat plate model and the associated values of phase-averaged lift forces are presented in Table 5. The discrepancies between the phase-averaged lift forces obtained on the three grids are minimal. The values of phase-averaged lift forces obtained from both the experiments and the simulations for all wing models are also presented in Table 6. The difference between the experimental results and the computational results for the fine grid of the flat plate model is approximately 3.57%. Hence, the results obtained from the fine grid are discussed in this paper.
The pressures at all cells of the desired boundary surfaces pi are integrated to obtain the net pressure difference P around the wing. To obtain the lift force per unit span L, the resulting net pressure difference P is multiplied by the projected area per unit span of each wing Ax.
L = P. Ax
Because the area per unit span “A” is the chord length times one, A = c × 1, the projected area per unit span “Ax” is the projected length of the wing times one.

4. Experimental and Computational Results

4.1. Kutta–Joukowski Theorem and Direct Force Measurement

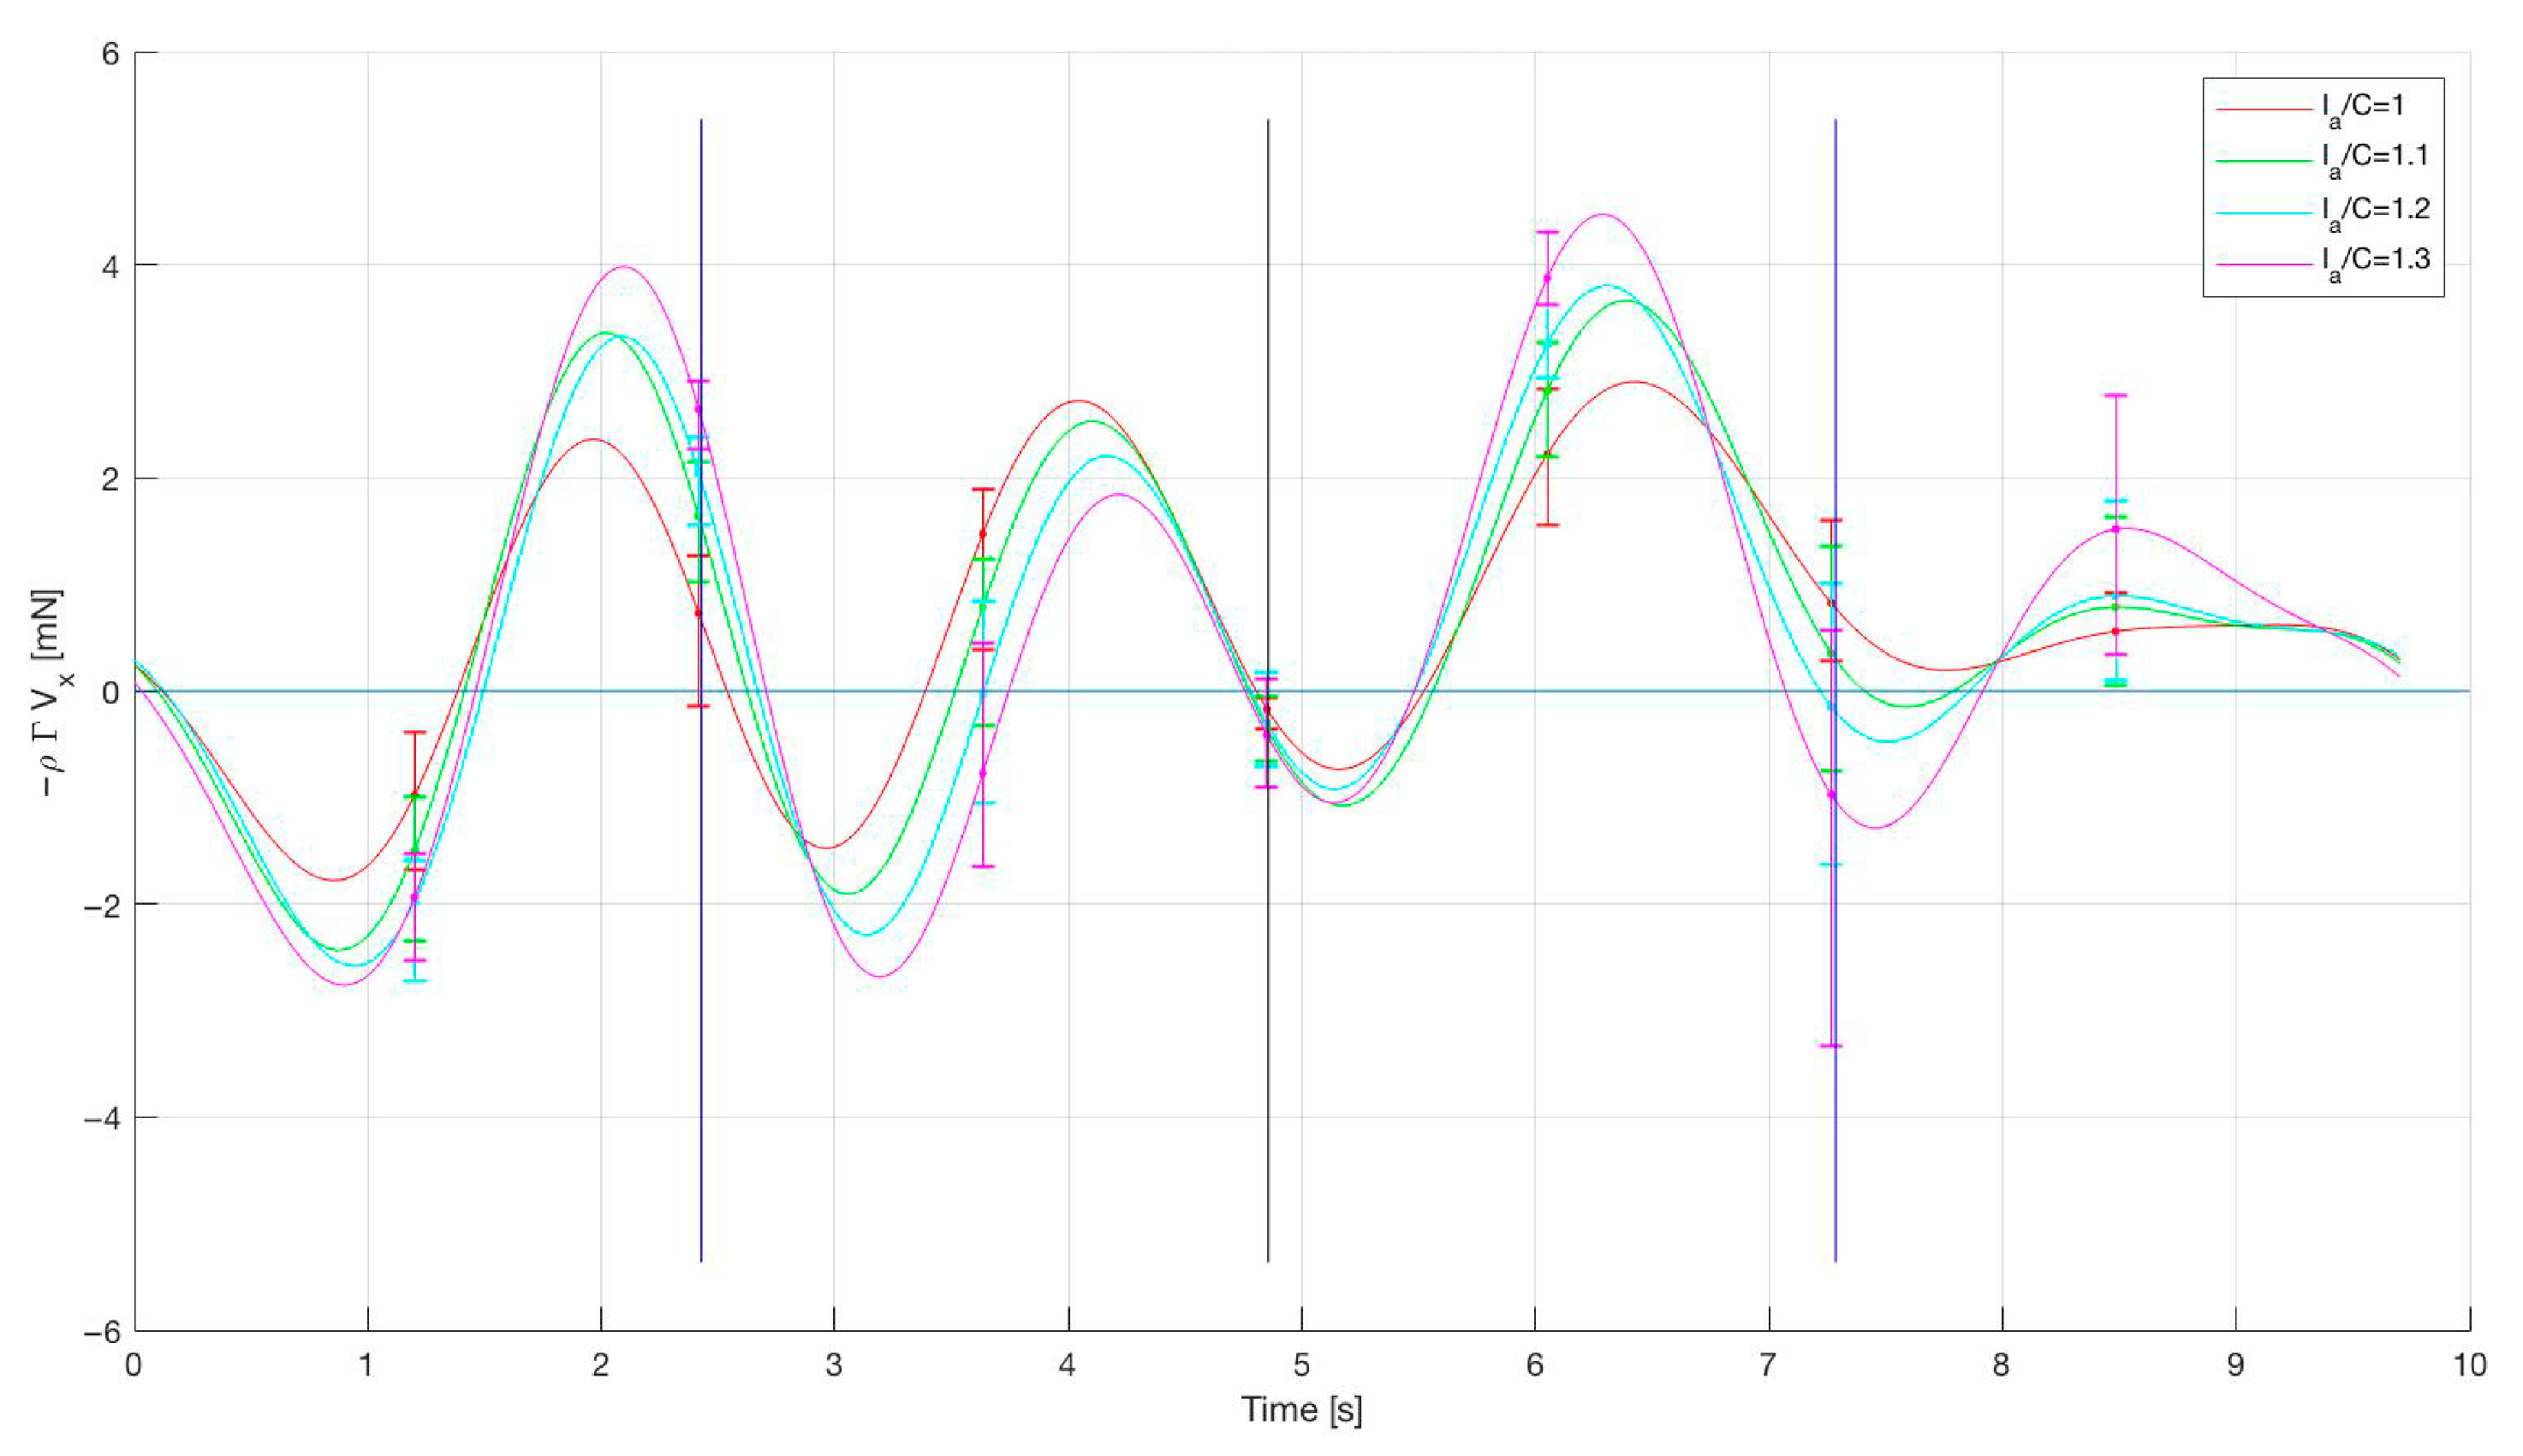
The lift predictions for the flat plate model for different control area side lengths, la, according to the Kutta–Joukowski theorem are shown in Figure 18. Zero lift is reached at the beginning of the stroke and at mid-stroke. Lift variation is symmetrical, and there is not much difference between the different control area side lengths, la, used.
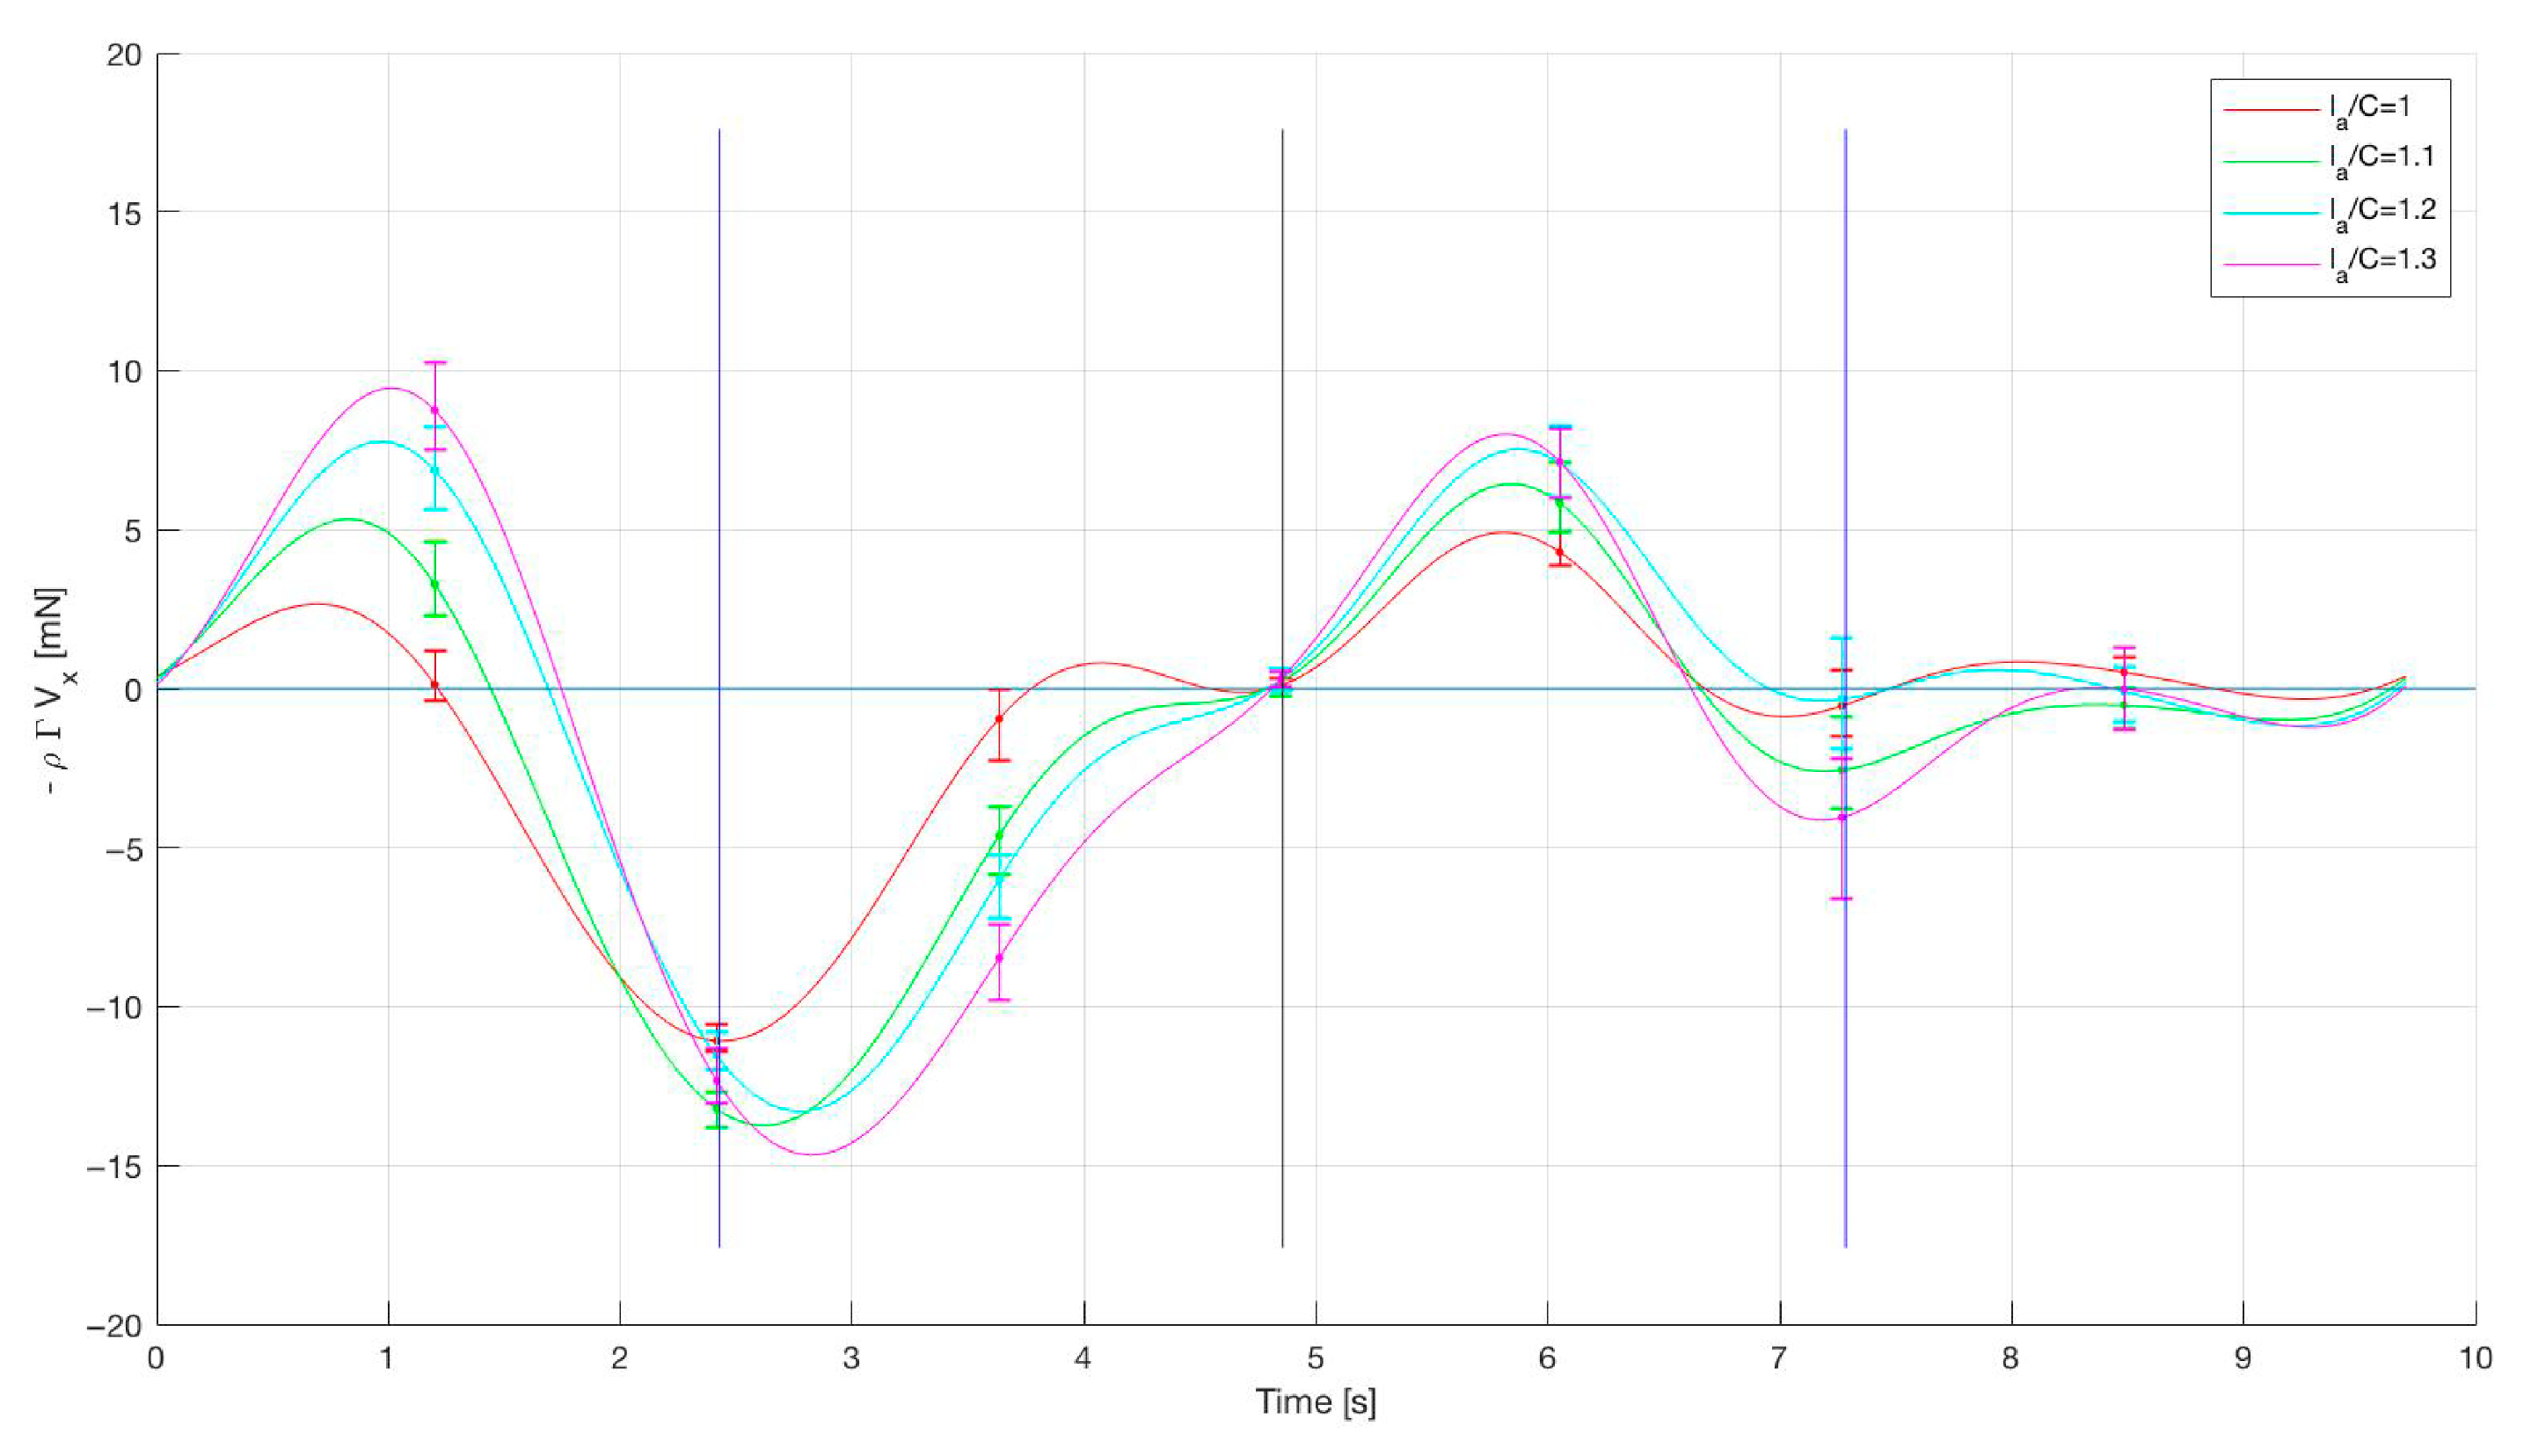
Lift predictions for the circular cylinder model for different control area side lengths, la, according to the Kutta–Joukowski theorem are shown in Figure 19. Once more, there is zero lift at the beginning of the stroke and at mid-stroke. According to the Kutta–Joukowski theorem, if velocity equals zero, so does lift. However, because of the wake capture or even the added mass, determining that the velocity of the flow is exactly the opposite of the translational wing velocity rests on significant assumptions. Moreover, the lift curve is not truly symmetrical. Indeed, the end of the downstroke is quite different from the end of the upstroke, including, in particular, the amplitude of the force.
Lift predictions for the elliptical cylinder model for different control area side lengths, la, according to the Kutta–Joukowski theorem are shown in Figure 20. Zero lift is also reached at the beginning of the stroke and at mid-stroke. Lift variation is not entirely symmetrical, but it follows essentially the same trend.
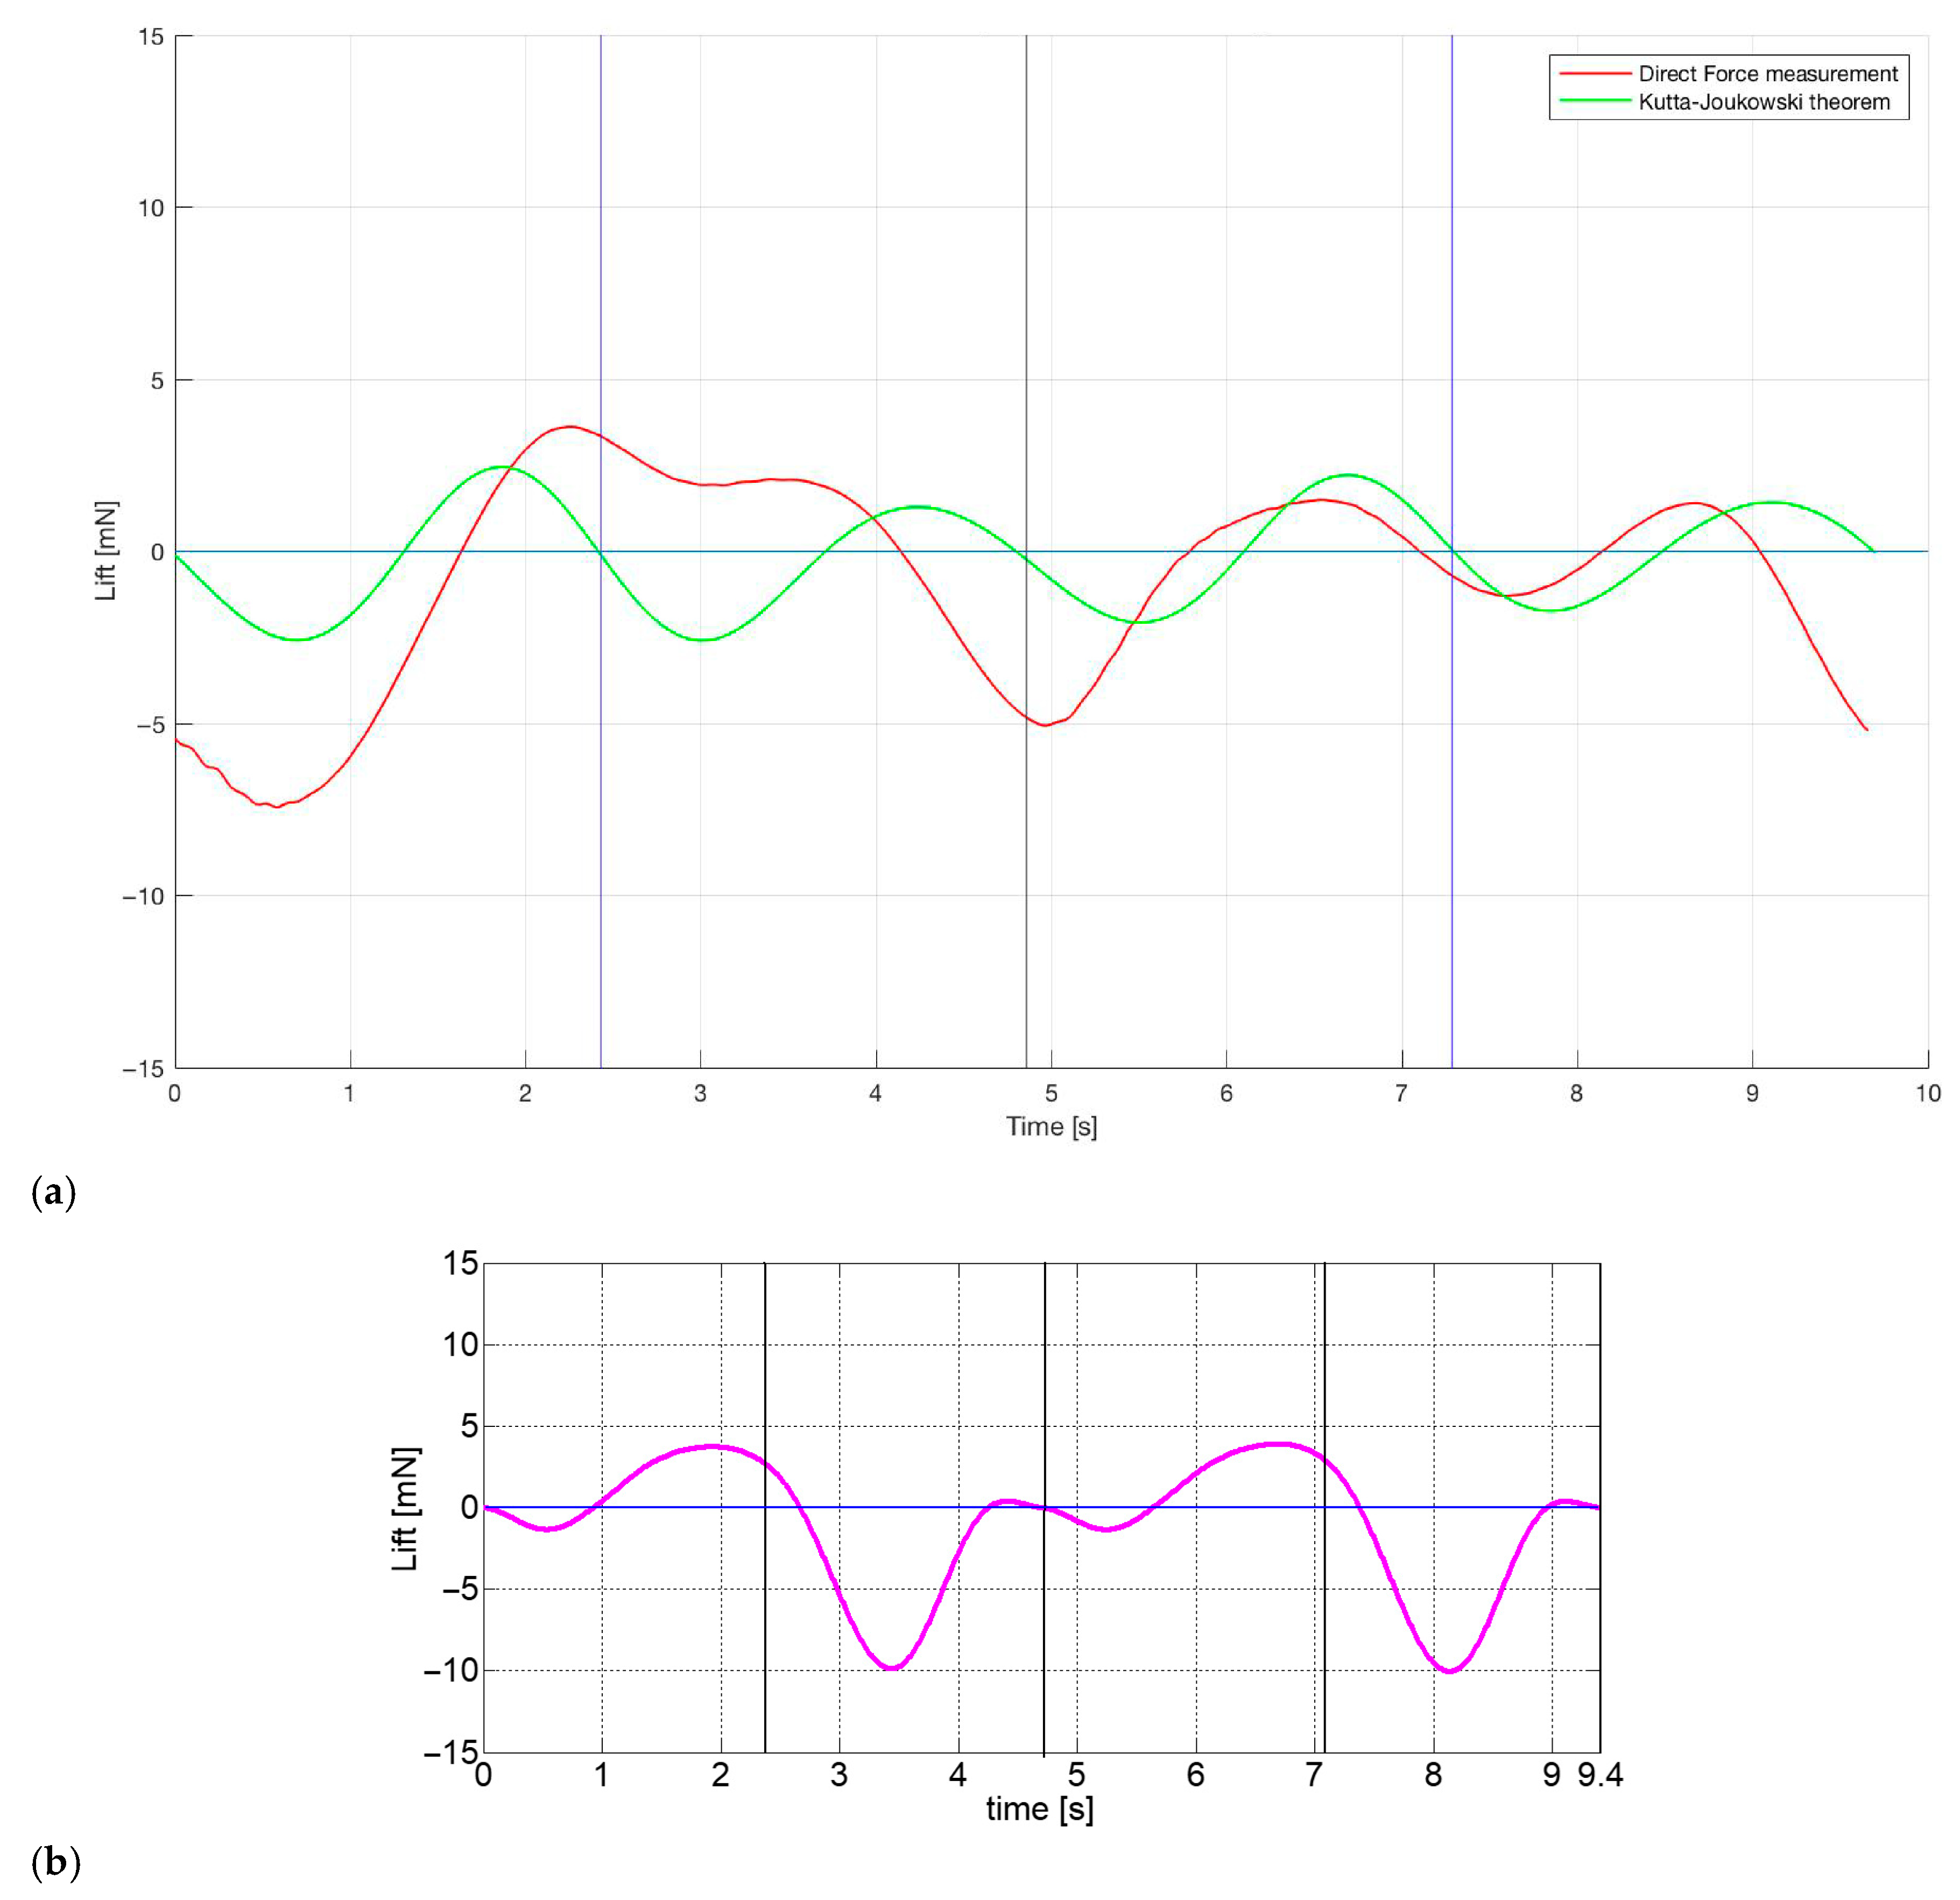
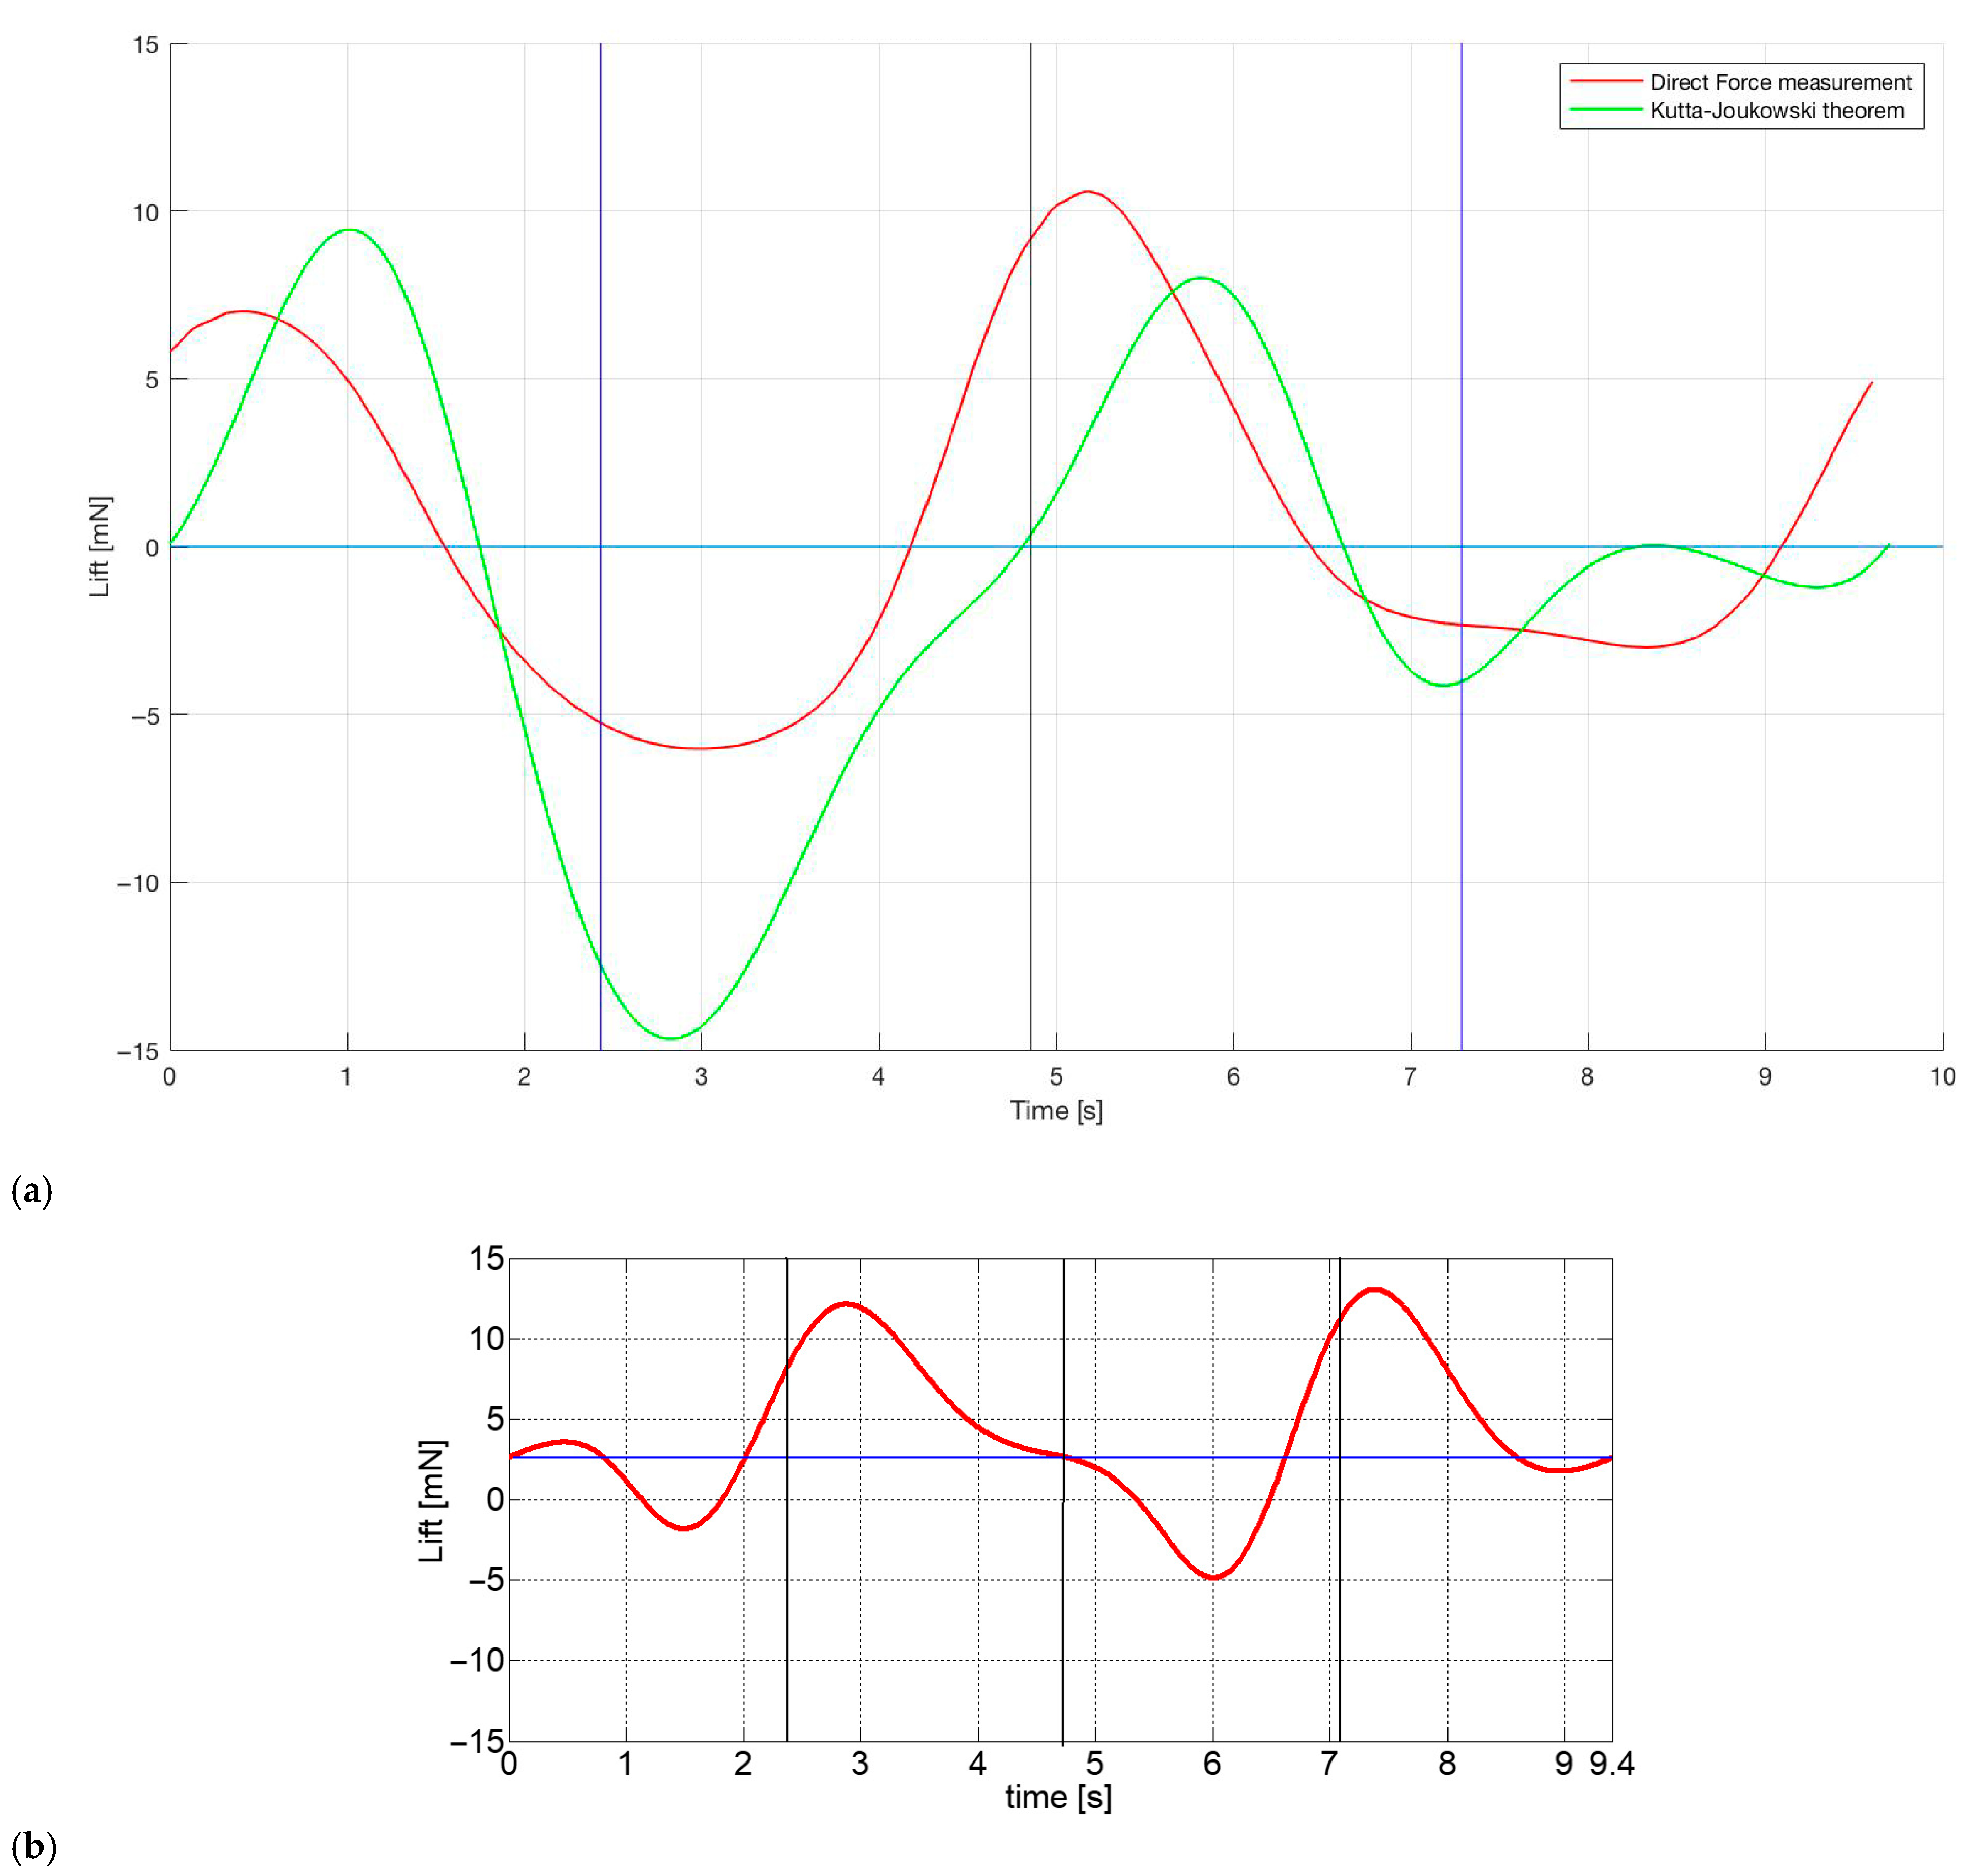
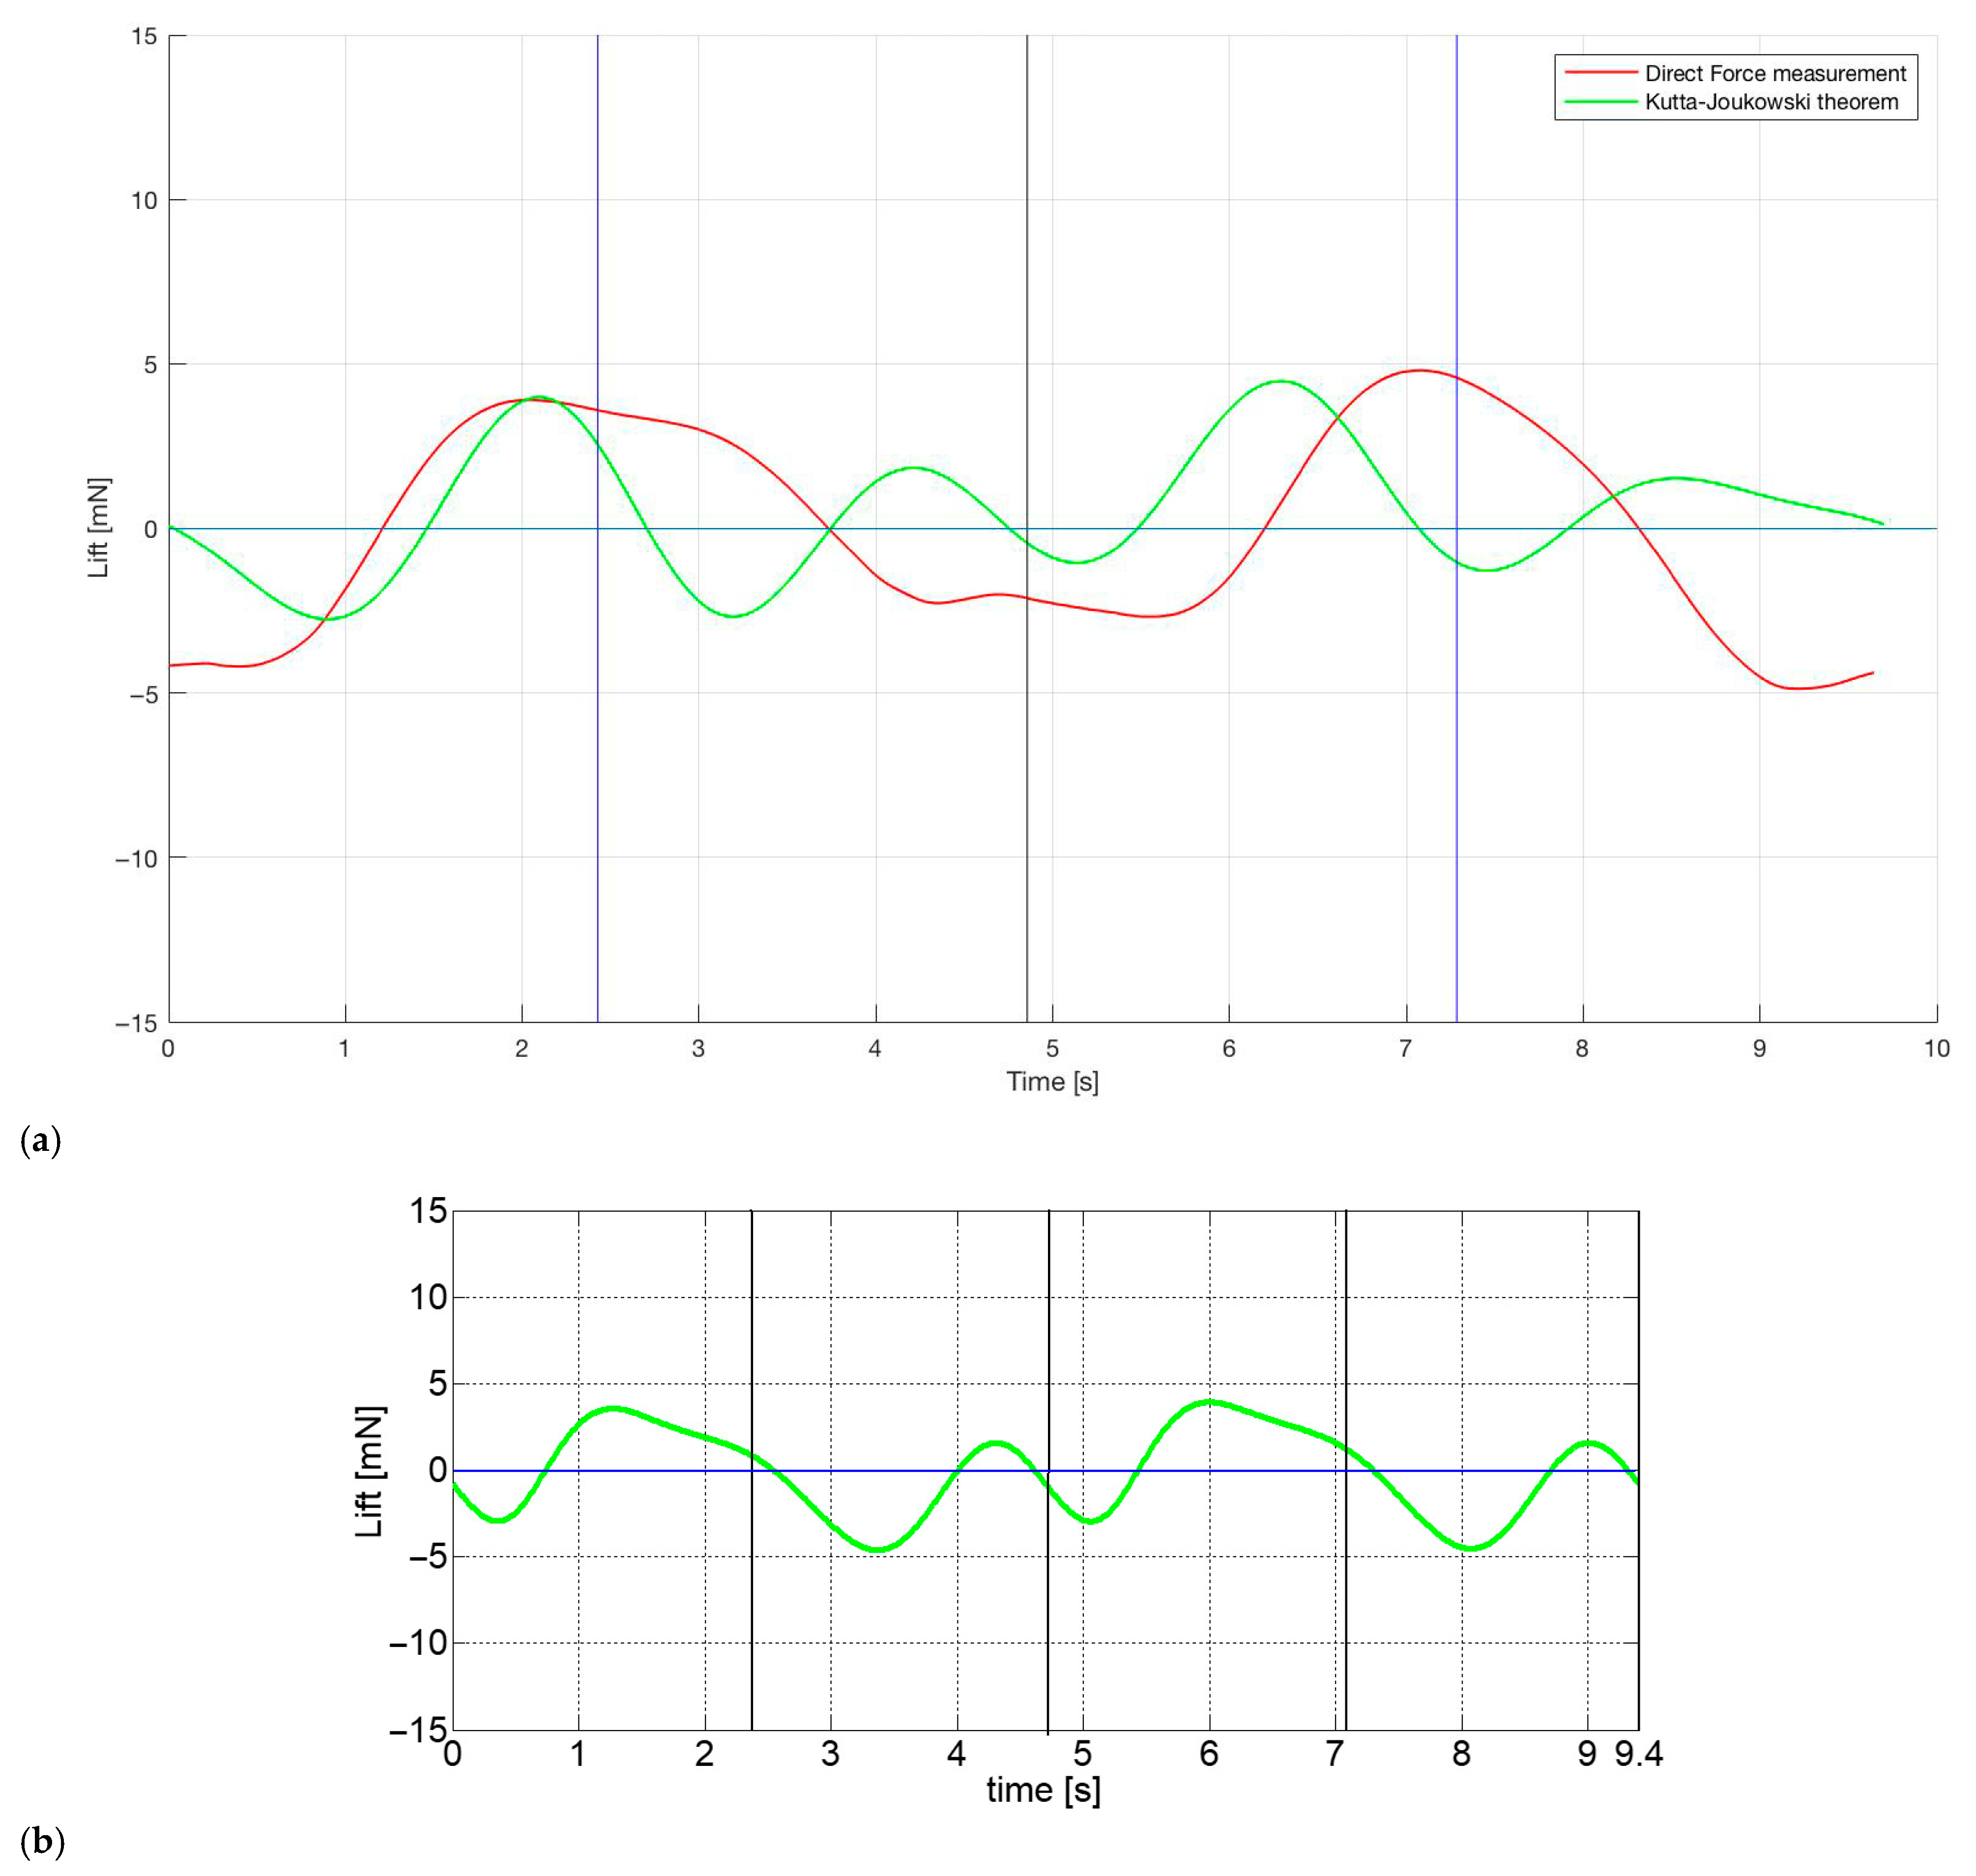
A comparison between direct force measurement and lift prediction based on the Kutta–Joukowski theorem for all cases is shown in Figure 21a, Figure 22a and Figure 23a. For the comparison with the direct force measurement, lift prediction according to the Kutta–Joukowski theorem for la/C = 1.3 is used for all cases.
In all cases, zero lift is reached at the beginning of the stroke and at mid-stroke. According to the Kutta–Joukowski theorem, if velocity equals zero, lift will be zero.
In the flat plate model, the average trend and amplitude mostly fit well. However, some unsteadiness, such as added mass or the wake capture effect, impact the measured lift. Indeed, the measured lift seems to be offset from both the Kutta–Joukowski prediction and computation.
In the circular cylinder model, the trend and the average amplitude seem to fit reasonably. However, unsteadiness is present due to the added-mass effect and wake capture. However, the prediction of the Magnus effect appears to be good due to the Kutta–Joukowski theorem. The end of the downstroke is quite different from the end of the upstroke. In particular, the amplitude of the force and the lift curve are not symmetric.
In the elliptical cylinder model, the Kutta–Joukowski prediction includes more variations in lift than the direct force measurement. It seems that the unsteady nature of the motion smooths the actual variation in lift.

4.2. Comparison Between Experimental and Computational Results

To observe the similarities in the flow structures and force generation, the computational results are qualitatively compared with the experimental results of Samuel et al. [20].
As shown in Figure 21 and Figure 23, the computational results (Figure 21b and Figure 23b) show a similar trend to the experimental results (Figure 21a and Figure 23a) for both flat plate and elliptical models. The general lift trend is well-predicted, offset by approximately 0.8 s, by the Kutta–Joukowski prediction. Symmetric lift peaks during a flapping cycle are observed in the computational results. On the other hand, a slight difference in the magnitude of lift peak and force patterns is observed between the upstroke and the downstroke of the circular cylinder model. Although the magnitudes of lift peaks in all cases are different from the experimental results, the magnitudes of phase-averaged lift per unit span are almost identical.
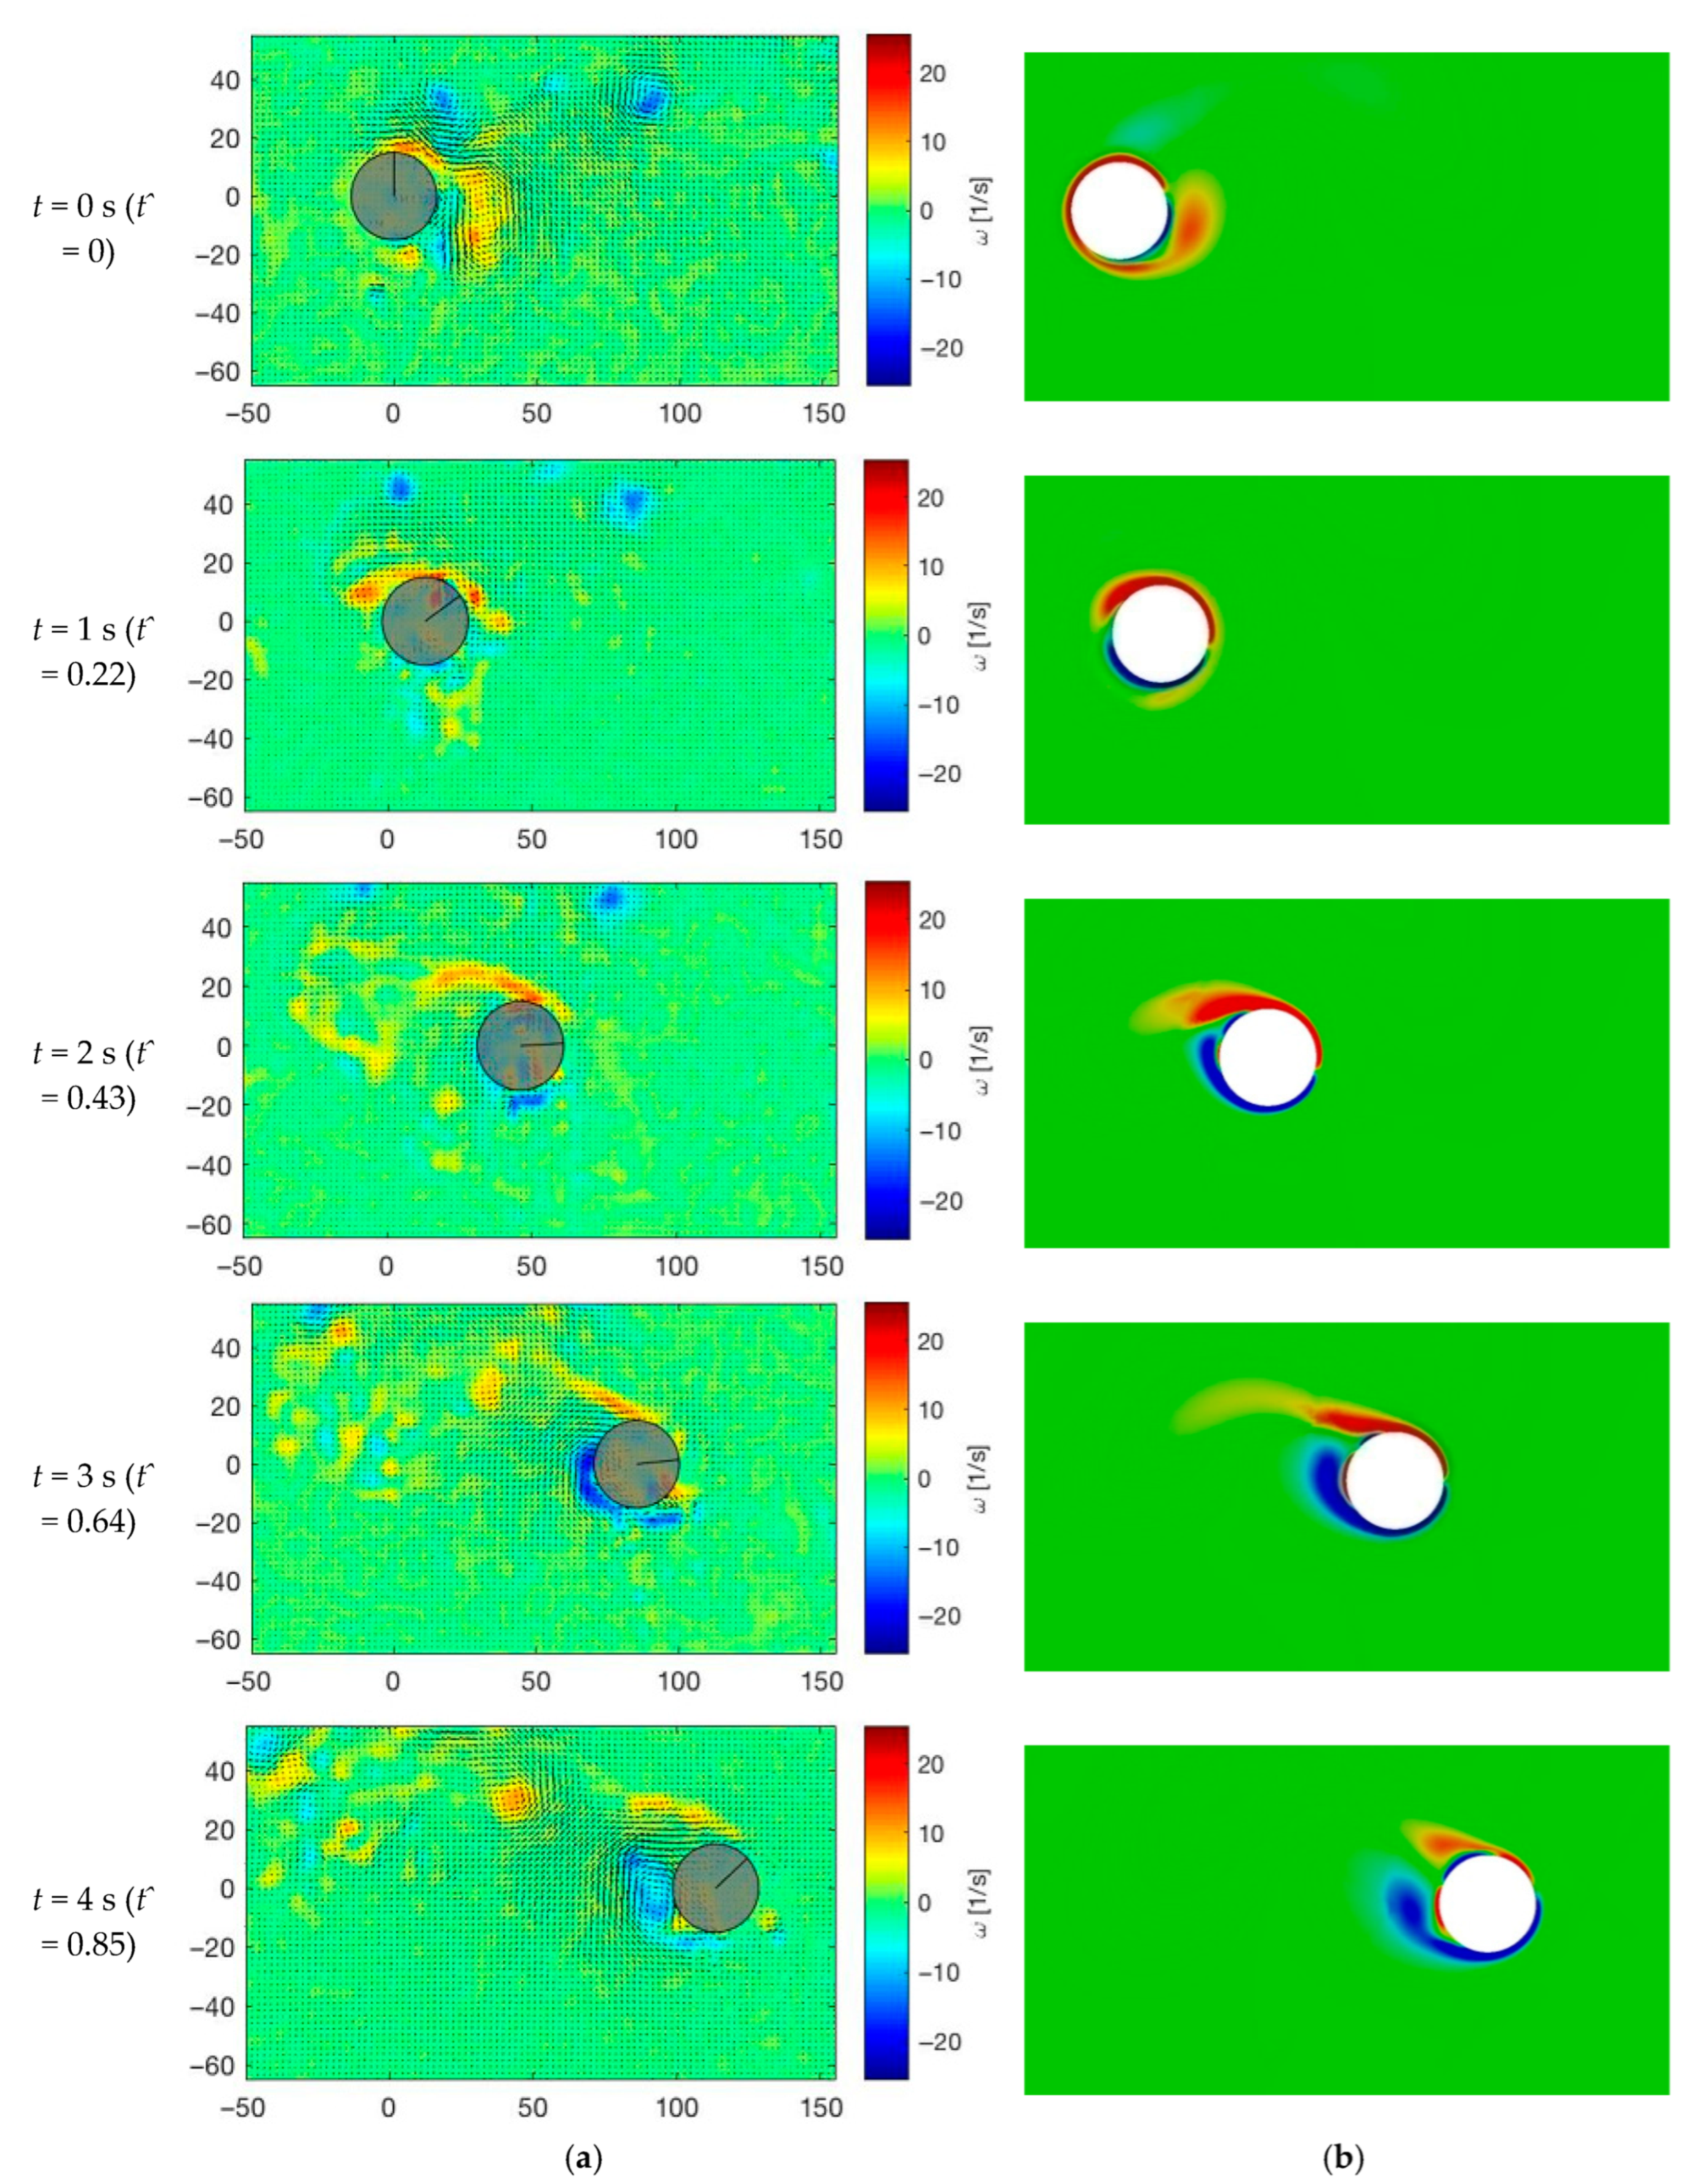
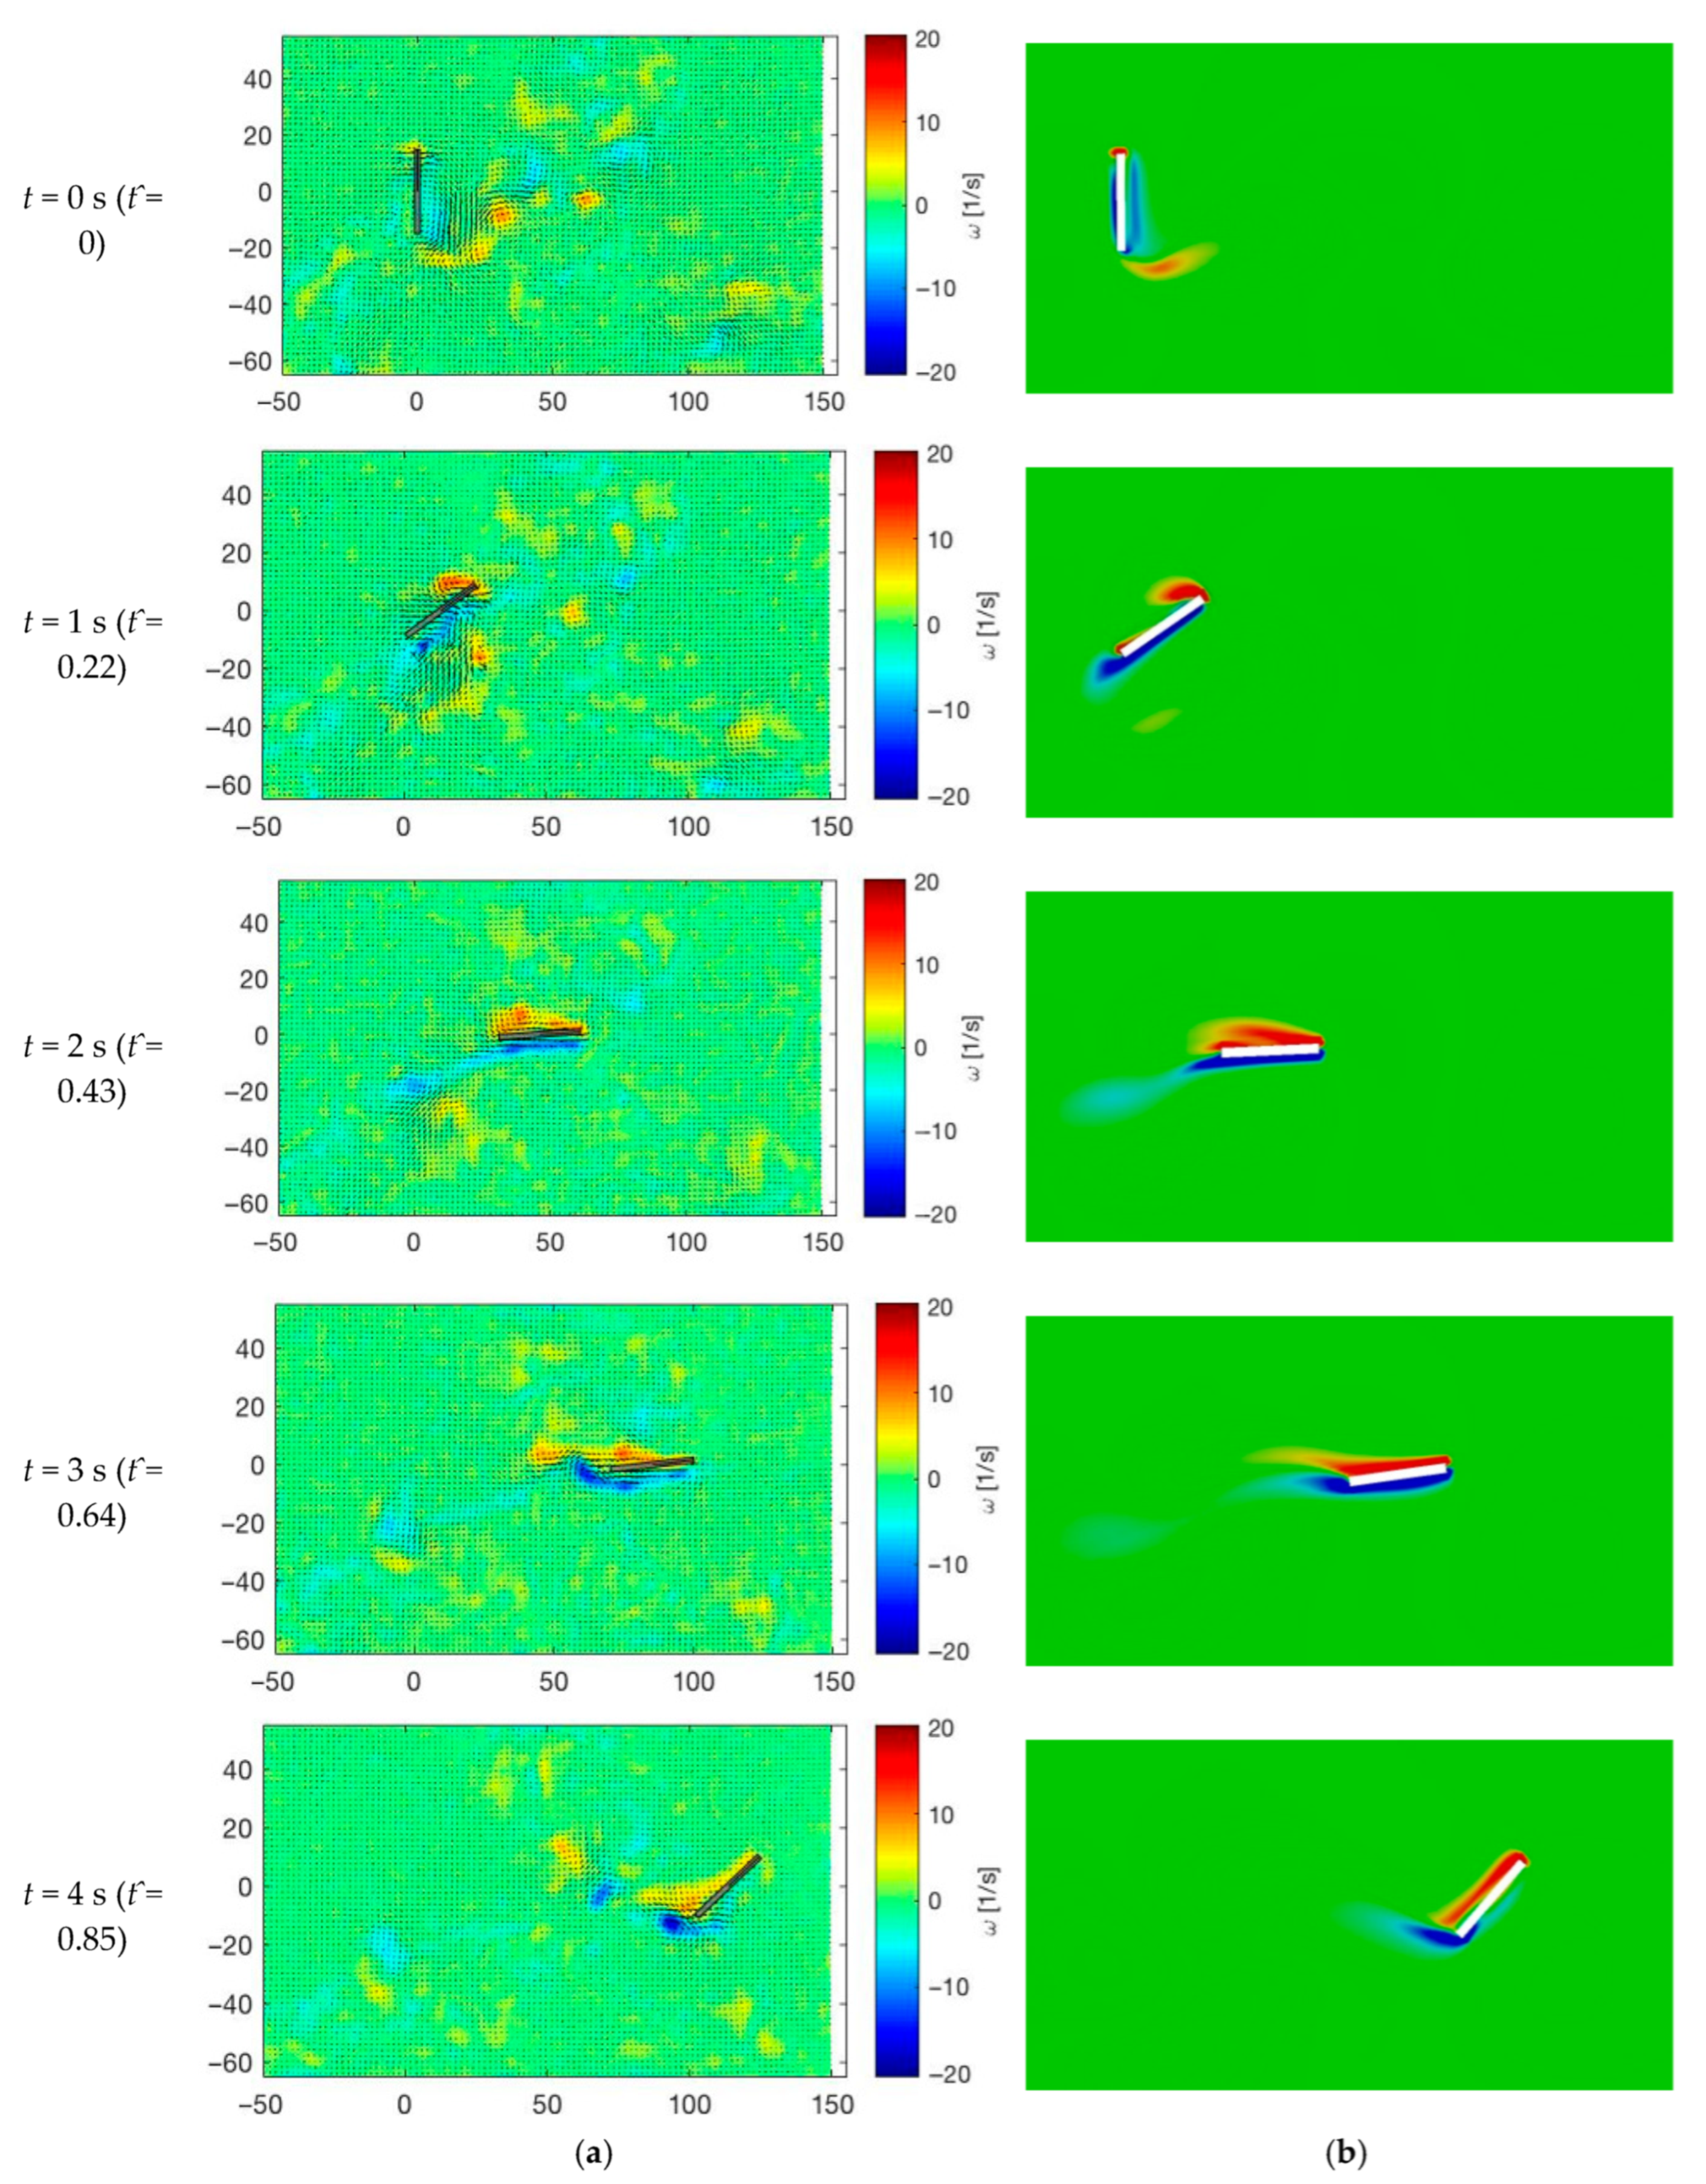
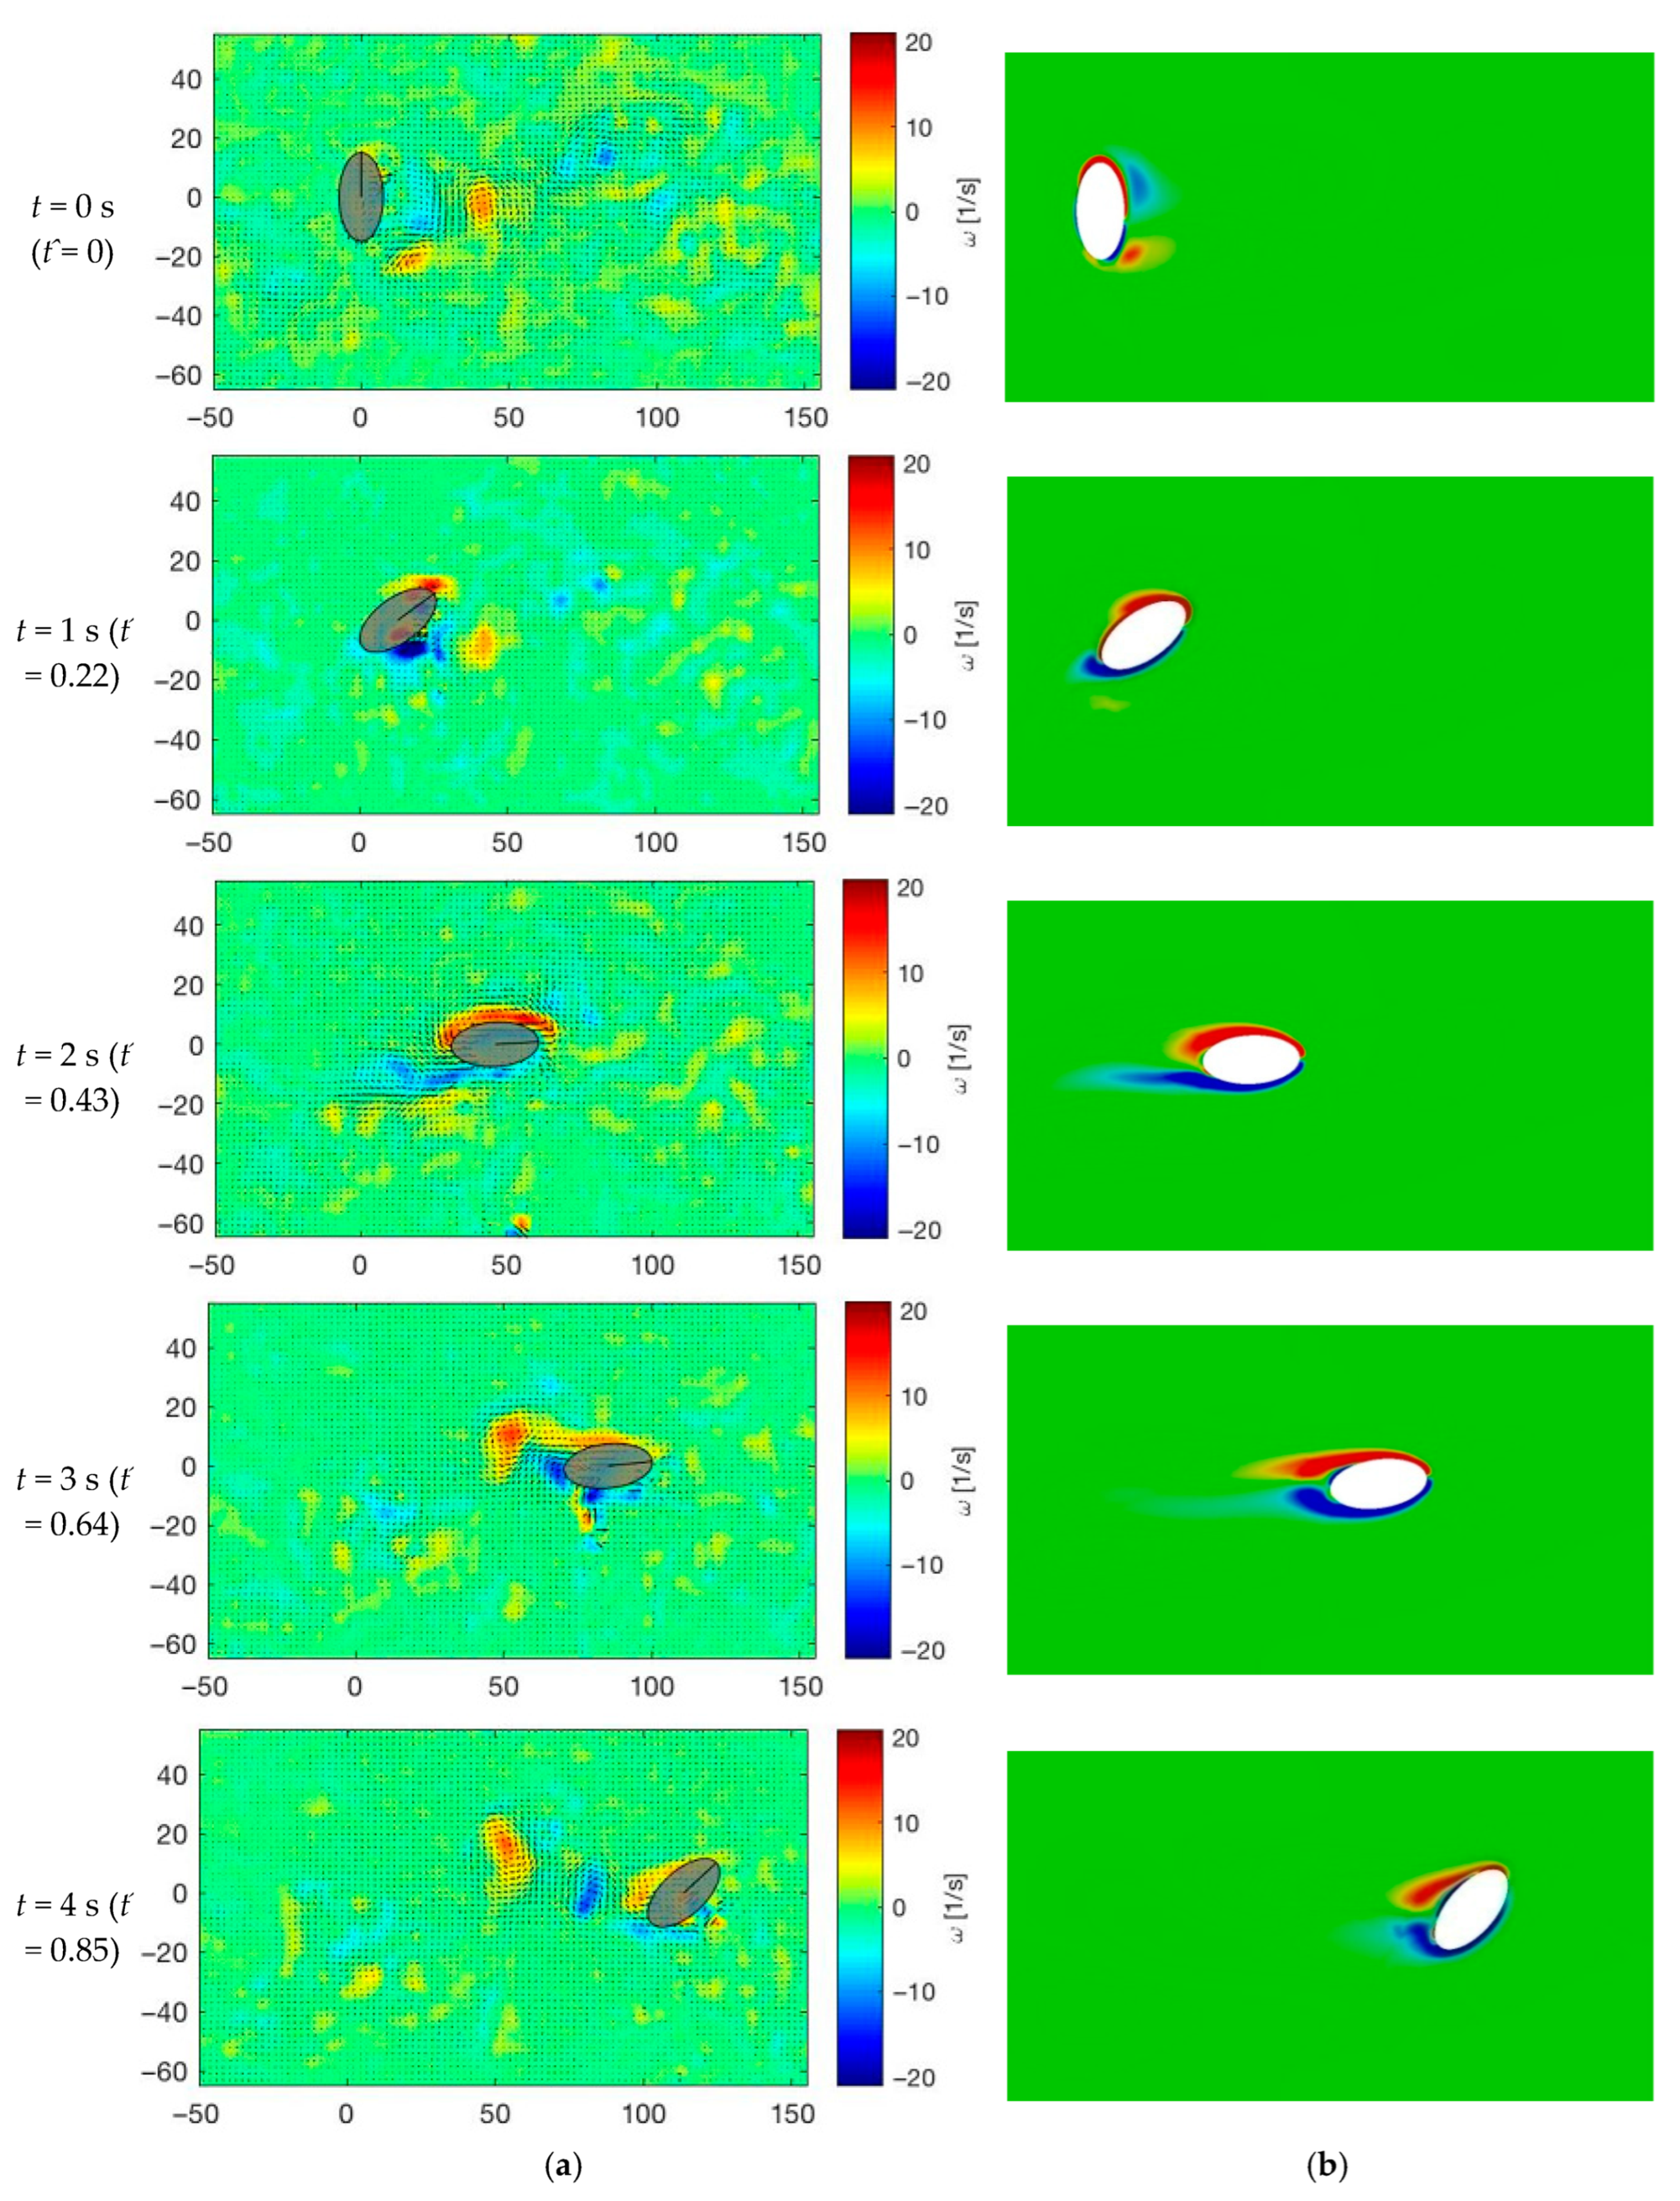
The comparisons of the computed vorticity field with the PIV results for all cases are shown in Figure 24, Figure 25 and Figure 26. The vorticity fields computed using the current computational method show good agreement in terms of predicted flow.

4.3. Lift and Flow Structures

We can now analyze the results obtained from the PIV experiment and computation. The PIV experiment was over 15–32 cycles, and a fully developed flow was confirmed. All strokes are similar, and analyzing one half cycle is sufficient. The computational results are taken from the tenth flapping cycle.

4.3.1. Flat Plate Model

The flow field around the flat plate model can be seen in Figure 24. From 0 to 2.5 s (t^ = 0 to 0.53), at the beginning of the stroke during the pronation phase, there is mixture of counter-clockwise vorticity (in red) and clockwise vorticity (in blue) due to the previous stroke. After 1 s (t^ = 0.22), a starting vortex (in blue) is created at the trailing edge. As a response, a bound vortex (counter-clockwise vorticity) (in red) is created at the leading edge and increases the circulation and then the lift. The lift force increases, as shown in Figure 21a.
After 2.5 s (t^ = 0.53), during mid-stroke, this vortex is slowly detached and washed away. The lift decreases to the minimum value. Note that it is difficult to fully distinguish the impact of this LEV over the pure translational lift due to the positive angle of attack and the translation motion. However, this leading-edge vortex may increase the critical angle of attack when the stall occurs.
From 3 to 4.5 s (t^ = 0.64 to 0.96), during the supination phase, while the vorticity is swiped away, the lift mainly varies according to the translational velocity. At t = 3.5 s (t^ = 0.75), a counterclockwise vorticity appears at the leading edge and will grow at t = 4 s (t^ = 0.85). This seems to be the starting vortex created because of the quick supination. This fast rotation breaks the Kutta–Joukowski condition that needs to be re-established. However, we do not notice any bound vortex or clockwise vorticity at the trailing edge. Hence, this is likely responsible for the increase in lift.
Indeed, we do not observe any lift production at the end of the stroke. Even if the slightly higher positive lift peaks before the end of the stroke, it does not seem to be relevant. At t = 4.5 s (t^ = 0.96), this starting vortex disappears with no trace of a bound vortex. When the translation ends, the lift reaches zero, and the wing goes back in order to continue its motion.

4.3.2. Circular Cylinder Model

The flow field around the circular cylinder model is illustrated in terms of spanwise vorticity and can be seen in Figure 25. From 0 to 1 s (t^ = 0 to 0.22), at the beginning of the stroke during the pronation phase, we notice a mix of counter-clockwise vorticity (in red) and clockwise vorticity (in blue) created during the previous stroke. From 0.5 to 1 s (t^ = 0.11 to 0.22), shear vorticity is created above and under the cylinder, and a vortex is detected on the upper left of the cylinder. This indicates that the flow above the cylinder is slower than the flow under the cylinder, which causes the vortex to be created where the two flows meet. This phenomenon induces an inverse Magnus effect and produces negative lift. At this moment, the motion’s unsteady nature is observed in the profile of lift force. Since the cylinder is rotating clockwise while translating to the right, negative lift is generated due to an inverse Magnus effect. However, as seen in Figure 22a, the lift force becomes negative only after approximately 1.5 s (t^ = 0.32). Indeed, the cylinder is still subject to the previous Magnus effect. This may be due to the added-mass effect occurring with the previous deceleration of the wing.
From 1.5 to 2.5 s (t^ = 0.32 to 0.53) during mid-stroke, the rotational velocity decreases and the shear vorticity is slowly detached and swiped away. However, it is also at this moment that the inverse Magnus effect is exerted on lift generation. Here, lift decreases and becomes negative. From 2.5 to 4.5 s (t^ = 0.53 to 0.96), during the supination phase, a positive Magnus effect is observed. Shear vorticity is created above and under the cylinder, and a vortex is detected behind the cylinder. This vortex is located slightly below y = 0 mm at 3.5 s (t^ = 0.75), which indicates that the flow is faster above the cylinder than under the cylinder and a positive Magnus effect is observed. This phenomenon induces a relative pressure difference and produces lift. As the translational velocity approaches zero, the strength of shear vorticity fades. On the other hand, the unsteady motion causes non-zero lift production, still subject to the Magnus effect. The circular cylinder will then go back in order to complete its cycle, and the others afterwards.

4.3.3. Elliptical Cylinder Model

The flow field around the elliptical cylinder model can be seen in Figure 26. From 0 to 2.5 s (t^ = 0 to 0.53), at the beginning of the stroke during the pronation phase, we again notice a mix of counter-clockwise vorticity (in red) and clockwise vorticity (in blue) due to the previous stroke. After 1 s (t^ = 0.22), a counterclockwise vorticity is created. But no vortex is detected on the Q criterion graph as seen in Figure 27, and this circulation does not seem to be due to a leading-edge vortex whatsoever. The increase in lift might be due only to the translational lift. After 2 s (t^ = 0.43) during mid-stroke, this vorticity is slowly detached and swiped away. During this moment, the lift mainly varies according to the translational velocity. A lift peak is noticed at mid-stroke while the translational velocity reaches its maximum. As was the case at the beginning of the stroke, only shear vorticity is actually created and no trace of the starting vortex that would indicate the presence of the Kramer effect is observed. From 3 to 4.5 s (t^ = 0.64 to 0.96), at the end of the stroke during the supination phase, the translational velocity reaches zero and the lift decreases, even becoming negative, possibly because we reach the stall angle but also because of the added-mass effect. Indeed, when the wing decelerates, the fluid seems to go faster than the wing. In consequence, the angle of attack acts as if it were negative and then produces negative lift. Finally, the wing goes back in order to continue its motion.

5. Discussion

5.1. The Kramer and Magnus Effects

5.1.1. The Flat Plate Model and Kramer Effect

It is actually difficult to notice the presence of the Kramer effect for the flat plate model. Indeed, in the direct force measurement, the lift essentially follows the expected translational lift, and other important effects, such as wake capture or added-mass effects, interfere with the rotational lift that we have tried to focus on. If we examine the qualitative PIV and computational results, we notice a starting vortex created at the end of the stroke, when the Kutta–Joukowski condition needs to be re-established. However, we observe no trace whatsoever of the bound vortex that is supposed to increase the circulation and then the lift. No additional circulation is actually observed at the end of the stroke. The Kutta–Joukowski theorem predicts a maximum lift peak that is 30 percent higher and a minimum that is twofold lower. However, the general trend fits relatively well. The peaks are offset by less than 0.5 s (t^ = 0.11) along all strokes, even considering that the velocity used for the Kutta–Joukowski theorem is simply the translational velocity of the wing.
Note that although the surface roughness of the wing can greatly affect the generation and strength of the vortex, the present study is limited to a smooth surface of the wing and does not consider the impact of surface texture on the generation of the vortex. In a supplementary numerical case performed with altered translational and rotational rates, we did not observe any trace of the bound vortex that is supposed to increase the circulation and then the lift.

5.1.2. The Circular Cylinder Model and Magnus Effect

The circular cylinder model was chosen to be the reference blunt body to observe the Magnus effect. Although the lift appears to be offset by about 1.6 s (t^ = 0.35) from the expected trend due to quasi-steady or unsteady effects, we do notice the Magnus effect. Indeed, according to the translation and rotation motions, we would expect the lift to first be negative. However, it first increases, with positive lift of about 6 mN at the beginning of the stroke. The general lift trend is actually well predicted, offset by about 0.6 s (t^ = 0.13), by the Kutta–Joukowski theorem, and it is consistent with the PIV results. The maximum lift is reached 0.4 s (t^ = 0.09) after the supination and pronation and is 20 percent higher than the Kutta–Joukowski lift prediction. On the other hand, the minimum peak is reached 0.5 s (t^ = 0.11) after mid-stroke and is two times lower than the Kutta–Joukowski prediction.

5.1.3. The Elliptical Cylinder Model

The elliptical cylinder model is not blunt enough to behave like the circular cylinder model and thus to observe the presence of the Magnus effect. In terms of the amplitude or the trend of the graph, the lift production of the elliptical cylinder model has nothing to do with the circular cylinder model. On the other hand, the elliptical cylinder model is not sharp enough to behave like the flat plate model and then to observe the presence of the Kramer effect. The lift responses for the elliptical cylinder model and for the flat plate are pretty similar. However, the elliptical cylinder model produces a maximum lift peak 20 percent higher and a minimum one 40 percent lower than the flat plate model. The peaks occur almost at the same time, even if two more fluctuations, after 3 and 7.5 s (t^ = 0.64 and 1.6), are observed for the flat plate model. The last one is actually significant because it leads the lift to go below zero while it reaches its maximum for the elliptical cylinder model. The problem is that the presence of the translational lift, as well as other unsteadiness, prevents us from bringing out a potential Kramer effect and clearly elucidating the rotational lift’s origin. Furthermore, it has been said previously that no trace of the bound vortex due to the Kramer effect was found, even in the case of the flat plate model. However, neither the leading-edge vortex at the beginning of the stroke nor the starting vortex at the end is observed. From this point of view, the elliptical cylinder model appears not to be sharp enough.
For the elliptical cylinder model, the major axis is 30 mm, the minor axis is 15 mm, and the eccentricity is e = √2. This elliptical section with an aspect ratio of 2 is not blunt enough to observe the Magnus effect and not sharp enough to allow the Kutta–Joukowski condition to be re-established. Other wing shapes could be taken into account in order to find the critical eccentricities of the elliptical cylinder that could cause either the Magnus or Kramer effect to occur.

5.2. Comparison of the Three Wing Models

In general, the flow structures around the three different types of wings have been simulated reasonably well by the current computations. The results for the flat plate model, the circular cylinder model, and the elliptical cylinder model are compared in Figure 21, Figure 22 and Figure 23.
In these figures, we can first observe the similarity between the elliptical cylinder and flat plate models compared to the circular cylinder model. Thus, of course, translational lift occurs in both cases and, coupled with the added-mass effect occurring during the previous deceleration, causes negative lift at the beginning of the stroke. Significant lift amplitude is observed for the circular cylinder model when compared with the other two models. Indeed, the maximum lift produced by the circular cylinder model is about 3 times higher than that produced by the flat plate model and about 2 times higher than that produced by the elliptical cylinder model. However, the minimum lift observed for the circular cylinder model is as low as that for the elliptical cylinder model and even higher than that for the flat plate model.
Regarding the phase-averaged lift, the circular cylinder model produces 4.8 times more lift than the flat plate model, but the section lift coefficient remains 2.08 times lower due to the thin thickness of the flat plate.
The maximum lift peaks for the circular cylinder model occur at the same moment as the minimum lift peaks for the two other cases, and vice versa. These peaks occur from 0.1 to 1 s (t^ from 0.02 to 0.22) after supination, pronation, or mid-stroke. The lift reaches zero from 0.1 to 1.5 s (t^ from 0.02 to 0.32) before supination, pronation, or mid-stroke, which characterizes the unsteady nature of the motion. Indeed, we would expect to observe these zero responses at supination, pronation, or mid-stroke when the translational velocity, rotational velocity, or angle of attack equals zero.
The different lift trends according to the Kutta–Joukowski theorem are more similar. Indeed, this is because the definition involves what we assume to be the wing velocity, which is then the same for every model. For all the models, the Kutta–Joukowski theorem fits well with the direct force measurements, even though we notice, logically, a zero lift at the beginning of the stroke and at mid-stroke. This is not the case for the direct force measurements. This demonstrates the effect of significant unsteadiness, such as wake capture or added-mass effects, on the total lift production. The measured lift peaks are always offset by less than 1 s (t^ = 0.22) from the Kutta–Joukowski prediction. The range of lift produced by the circular cylinder model is 25 percent narrower than predicted. On the other hand, the ranges of lift produced by the two other models are about 40 percent wider than predicted.
The general lift trends in the numerical simulations resemble the Kutta–Joukowski theorem for both the flat plate and elliptical cylinder models. As for the circular cylinder models, the general lift trends in the numerical simulations resemble the Kutta–Joukowski theorem only when the numerical results are mirrored. The source of this discrepancy may be computational inaccuracies or experimental errors.
Despite the results from the investigations described above, some details are unclear and require explanations in future work. The fundamental and efficient Kutta–Joukowski theorem has been used with the PIV results to predict lift production. Given the assumptions the theorem makes, it is important to note that it is a quasi-steady method. Other methods that include time derivatives might be useful. During direct force measurement, other unsteadiness sources are involved in lift production, such as the added-mass or wake capture effect. This makes the actual rotational lift contribution unclear, especially from a quantitative point view. By removing or estimating these effects, we may obtain more clarifying results that shed some light on MAV wing design and modeling.

6. Conclusions

Experiments and computation were performed to better understand the impact of supination and pronation on total lift production occurring at the end of the stroke when small insects flap their wings. Using the Reynolds number of a bumblebee, simplified sinusoidal translational and rotational velocity profiles were chosen. The focus was on the rotational lift, and so three wing profile sections were studied: a circular cylinder model as a reference for a blunt body, for which the well-known Magnus effect is expected to occur; a flat plate model as the reference for a sharp body, for which the Kramer effect is expected to occur; and finally, an elliptical cylinder model as a transition case. Direct force measurement and particle image velocimetry experiments were conducted to quantitatively obtain the lift produced and the surrounding flow structure. Moreover, under some assumptions, the Kutta–Joukowski theorem was applied to the PIV results to predict, in a quasi-steady state, lift production. The experimental results have been presented with the corresponding computational results. In general, there is good agreement between the experimental and computational results.
For the circular cylinder model, the Magnus effect is well-predicted by the Kutta–Joukowski theorem, and it aligns with the PIV results with the presence of opposite shear vorticity under and above the cylinder. For the flat plate model, it is difficult to notice the presence of the Kramer effect. According to the PIV and computational results, the leading-edge vortex emerges after 0.5 s (t^ = 0.11) at the beginning of the stroke. At the end of the stroke, when the Kutta–Joukowski condition needs to be re-established, the creation of a starting vortex is observed after 3.5 s (t^ = 0.75), but no trace of a bound vortex due to the Kramer effect is observable. The Kramer effect seems not to be involved in rotational lift production, even if Kutta–Joukowski conditions appear to be re-established.
The lift responses for the elliptical cylinder model and for the flat plate are fairly similar, but they also align with the presence of translational lift. However, neither the leading-edge vortex at the beginning of the stroke nor the starting vortex at the end of the stroke is observed. Furthermore, for the flat plate model, no trace of a bound vortex due to the Kramer effect is found. From this point of view, the elliptical cylinder model appears not to be sharp enough to re-establish the Kutta–Joukowski condition. Finally, it is important to note that remaining interference prevents a proper analysis of the origin of lift production for the flat plate and elliptical cylinder models. Indeed, the presence of translational lift as well as other unsteadiness makes it difficult to identify a potential Kramer effect and the rotational lift’s origin.


Author Contributions

Conceptualization, S.O. and S.V.; methodology, S.V. and M.H.W.K.; software, M.H.W.K.; validation, S.O., S.V. and M.H.W.K.; formal analysis, S.V. and M.H.W.K.; investigation, S.V. and M.H.W.K.; resources, S.V. and M.H.W.K.; data curation, S.V. and M.H.W.K.; writing—original draft preparation, M.H.W.K.; writing—review and editing, S.O.; visualization, S.O.; supervision, S.O.; project administration, S.O.; funding acquisition, S.O. All authors have read and agreed to the published version of the manuscript.

Funding

This research was funded by Keio University grant number 091946-2025 and AUN/SEED-Net JICA for funding at Keio University.

Institutional Review Board Statement

Not applicable.

Informed Consent Statement

Not applicable.

Data Availability Statement

Please contact the corresponding author for the data presented in this paper.

Conflicts of Interest

The authors declare no conflicts of interest.

Abbreviations

The following abbreviations are used in this manuscript:
PIVParticle image velocimetry
UAVsUnmanned air vehicles
BAVsBiomimetic air vehicles
LEVLeading-edge vortex
AoAAngle of attack
CFDComputational fluid dynamic
PISOPressure Implicit with Splitting of Operator

References

  1. Ellington, C.P. The novel aerodynamics of insect flight: Applications to micro-air vehicles. J. Exp. Biol. 1999, 202, 3439–3448. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  2. Hope, D.K.; DeLuca, A.M.; O’Hara, R.P. Investigation into Reynolds number effects on a biomimetic flapping wing. Int. J. Micro Air Veh. 2018, 10, 106–122. [Google Scholar] [CrossRef] [Scilit]
  3. Shyy, W.; Aono, H.; Kang, C.K.; Liu, H. An Introduction to Flapping Wing Aerodynamics; Cambridge University Press: Cambridge, UK, 2013. [Google Scholar]
  4. Dickinson, M.H.; Götz, K.G. Unsteady aerodynamic performance of model wings at low Reynolds numbers. J. Exp. Biol. 1993, 174, 45–64. [Google Scholar] [CrossRef] [Scilit]
  5. Cleaver, D.; Wang, Z.; Gursul, I. Delay of stall by small amplitude airfoil oscillations at low Reynolds numbers. In Proceedings of the 47th AIAA Aerospace Sciences Meeting Including the New Horizons Forum and Aerospace Exposition, Orlando, FL, USA, 5–8 January 2009; p. 392. [Google Scholar]
  6. Birch, J.M.; Dickinson, M.H. The influence of wing–wake interactions on the production of aerodynamic forces in flapping flight. J. Exp. Biol. 2003, 206, 2257–2272. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  7. Yan, X.; Zhu, S.; Su, Z.; Zhang, H. Added mass effect and an extended unsteady blade element model of insect hovering. J. Bionic Eng. 2011, 8, 387–394. [Google Scholar] [CrossRef] [Scilit]
  8. Sane, S.P.; Dickinson, M.H. The aerodynamic effects of wing rotation and a revised quasi-steady model of flapping flight. J. Exp. Biol. 2002, 205, 1087–1096. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  9. Dickinson, M.H.; Lehmann, F.O.; Sane, S.P. Wing rotation and the aerodynamic basis of insect flight. Science 1999, 284, 1954–1960. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  10. Sane, S.P. The aerodynamics of insect flight. J. Exp. Biol. 2003, 206, 4191–4208. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  11. Dickinson, M.H.; Götz, K.G. The wake dynamics and flight forces of the fruit fly Drosophila melanogaster. J. Exp. Biol. 1996, 199, 2085–2104. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  12. Sun, M.; Tang, J. Unsteady aerodynamic force generation by a model fruit fly wing in flapping motion. J. Exp. Biol. 2002, 205, 55–70. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  13. Dickinson, M.H.; Lehmann, F.O.; Götz, K.G. The active control of wing rotation by Drosophila. J. Exp. Biol. 1993, 182, 173–189. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  14. Seifert, J. A review of the Magnus effect in aeronautics. Prog. Aerosp. Sci. 2012, 55, 17–45. [Google Scholar] [CrossRef] [Scilit]
  15. Wang, Z.J.; Birch, J.M.; Dickinson, M.H. Unsteady forces and flows in low Reynolds number hovering flight: Two-dimensional computations vs robotic wing experiments. J. Exp. Biol. 2004, 207, 449–460. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  16. Crall, J.D.; Ravi, S.; Mountcastle, A.M.; Combes, S.A. Bumblebee flight performance in cluttered environments: Effects of obstacle orientation, body size and acceleration. J. Exp. Biol. 2015, 218, 2728–2737. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  17. Willmott, A.P.; Ellington, C.P. The mechanics of flight in the hawkmoth Manduca sexta I. Kinematics of hovering and forward flight. J. Exp. Biol. 1997, 200, 2705–2722. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  18. Baranyi, L. Lift and drag evaluation in translating and rotating non-inertial systems. J. Fluids Struct. 2005, 20, 25–34. [Google Scholar] [CrossRef] [Scilit]
  19. Tokumaru, P.T.; Dimotakis, P.E. The lift of a cylinder executing rotary motions in a uniform flow. J. Fluid Mech. 1993, 255, 1–10. [Google Scholar] [CrossRef] [Scilit]
  20. Verboomen, S. Experimental Study of Rotational Lift Production Under Insect Flapping Wing Conditions for Different Wing Section Profiles. Master’s Thesis, Keio University, Yokohama, Japan, September 2018. [Google Scholar]
  21. Swanson, T.; Isaac, K. Aerodynamics of Flapping and Plunging Wings using Particle Image Velocimetry Measurements. In Proceedings of the 47th AIAA Aerospace Sciences Meeting Including The New Horizons Forum and Aerospace Exposition, Orlando, FL, USA, 5–8 January 2009; p. 1271. [Google Scholar]
  22. Haller, G. An objective definition of a vortex. J. Fluid Mech. 2005, 525, 1–26. [Google Scholar] [CrossRef] [Scilit]
  23. Stalnov, O.; Ben-Gida, H.; Kirchhefer, A.J.; Guglielmo, C.G.; Kopp, G.A.; Liberzon, A.; Gurka, R. On the estimation of time dependent lift of a European starling (Sturnus vulgaris) during flapping flight. PLoS ONE 2015, 10, e0134582. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  24. Noca, F. On the Evaluation of Time-Dependent Fluid-Dynamic Forces on Bluff Bodies; California Institute of Technology: Pasadena, CA, USA, 1997. [Google Scholar]
  25. Thiagarajan, K.P.; Troesch, A.W. On the use of various contour shapes for evaluating circulation from PIV data. In Proceedings of the 13th Australasian Fluid Mechanics Conference, Monash University, Melbourne, Australia, 13–18 December 1998. [Google Scholar]
Figure 1. (a) Kramer effect illustration. On the right, the starting vortex due to the re-establishment of the Kutta–Joukowski condition. On the left, the resulting bound vortex. (b) Magnus effect illustration.
Applsci 16 00724 g001
Figure 2. (a) Experimental setup. (b) Experimental tank.
Applsci 16 00724 g002
Figure 3. (a) Flat plate model with chord length C = 0.03 m. (b) Circular cylinder model with diameter D = 0.03 m. (c) Elliptical cylinder model. Green = major axis = 0.03 m. Blue = minor axis = 0.015 m.
Applsci 16 00724 g003
Figure 4. (a) Translation distance assumption. (b) Definition of coordinates.
Applsci 16 00724 g004
Figure 5. The schematic diagram of the upstroke and downstroke for the translating and rotating wing. The leading edge is marked by the red circle.
Applsci 16 00724 g005
Figure 6. (a) Water tank configuration. (b) Wing location inside the water tank.
Applsci 16 00724 g006
Figure 7. Schematic diagram of a bumblebee wing.
Applsci 16 00724 g007
Figure 8. (a) Side view. (b) Upper view of the 3-wing models. A: The flat plate model. B: The circular cylinder model. C: The elliptical cylinder model.
Applsci 16 00724 g008
Figure 9. (a) Brass axis connecting the wing to the stepping motor with the strain gauges fixed to it. (b) Strain gauge configuration.
Applsci 16 00724 g009
Figure 10. Strain gauges’ position calibration setup.
Applsci 16 00724 g010
Figure 11. Sinusoidal strain gauges’ responses, which fit the expected results.
Applsci 16 00724 g011
Figure 12. Force–Voltage correlation calibration setup.
Applsci 16 00724 g012
Figure 13. Average lift over time for 32 cycles in case of a translational wing normal to the motion direction.
Applsci 16 00724 g013
Figure 14. (a) Side view of the particle image velocimetry setup. (b) Upper view of the particle image velocimetry setup.
Applsci 16 00724 g014
Figure 15. (a) Tracking process using the particle image velocimetry method. (b) Calibration board.
Applsci 16 00724 g015
Figure 16. (a) Schematic view of a two-dimensional computation domain. (b) Grid generation. The origin of the coordinate is at the center of the computational domain.
Applsci 16 00724 g016
Figure 17. Lift force generated by the flat plate model for three different grid sizes.
Applsci 16 00724 g017
Figure 18. The Kutta–Joukowski theorem lift prediction for the flat plate model.
Applsci 16 00724 g018
Figure 19. The Kutta–Joukowski theorem lift prediction for the circular cylinder model.
Applsci 16 00724 g019
Figure 20. The Kutta–Joukowski theorem lift prediction for the elliptical cylinder model.
Applsci 16 00724 g020
Figure 21. (a) Lift measurement and prediction from Samuel et al. [20] for flat plate model. Red = experimental measurements. Green = Kutta–Joukowski prediction. (b) Present computational results for flat plate model.
Applsci 16 00724 g021
Figure 22. (a) Lift measurement and prediction from Samuel et al. [20] for circular cylinder model. Red = experimental measurements. Green = Kutta–Joukowski prediction. (b) Present computational results for circular cylinder model.
Applsci 16 00724 g022
Figure 23. (a) Lift measurement and prediction from Samuel et al. [20] for elliptical cylinder model. Red = experimental measurements. Green = Kutta–Joukowski prediction. (b) Present computational results for elliptical cylinder model.
Applsci 16 00724 g023
Figure 24. Vorticity field for flat plate model: (a) PIV results and (b) computational results.
Applsci 16 00724 g024
Figure 25. Vorticity field for circular cylinder model: (a) PIV results and (b) computational results.
Applsci 16 00724 g025
Figure 26. Vorticity field for elliptical cylinder model: (a) PIV results and (b) computational results.
Applsci 16 00724 g026
Figure 27. Q criterion for elliptical cylinder model: (a) PIV results and (b) computational results.
Applsci 16 00724 g027
Table 1. Flow and motion parameters.
ReStRotation AmplitudeRotation PeriodCenter of Rotation
12000.2π/29.4 sx = 0, y = 0
Table 2. Voltage/Force correlation summary.
ModelPair of Strain Gauges 1Pair of Strain Gauges 2
Cylinder modelF [mN] ⟶ 226 × Volt [V] + 2.2F [mN] ⟶ 147.3 × Volt [V] + 0.7
Flat plate modelF [mN] ⟶ 210.5 × Volt [V] + 1.6F [mN] ⟶ 113 × Volt [V] + 1.1
Table 3. PIV equipment specifications.
LaserTracer ParticlesHigh-Speed CameraLens
DPGL-2W by Japan Laser, Tokyo, JapanNylon 12 (5 g)Fastcam SA3 (60 frames per second) by Photron, Tokyo, JapanMicro-Nikkor 55 mm f/2.8 by Nikon, Tokkyo, Japan
Table 4. Numerical schemes.
Numerical SchemesOption Used
ddtSchemesEuler
gradSchemesGauss linear
divSchemesGauss upwind
interpolationSchemesLinear
snGradSchemesLimited 0.5
Table 5. Characteristics of the three different meshes for the flat plate model.
MeshNo of MeshesPhase-Averaged Lift
l a v (mN/m)
Lift Coefficient c l
Coarse17,8929.984.16
Medium36,0009.463.94
Fine72,2408.383.49
Table 6. Phase-averaged lift values for all wing models.
TypeExperimentsSimulations
Flat plate8.1 mN/m8.38 mN/m
Circular cylinder38.8 mN/m38.64 mN/m
Elliptical cylinder1.2 mN/m1.17 mN/m
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content.