


Featured Application
The developed model can be applied as a component in microsimulation analyses of shared bus stop operations, allowing the assessment of passenger boarding and alighting efficiency, the optimisation of platform length, and supporting administrative decisions related to service organization and the admission of new operators.
Abstract
With the growing heterogeneity of public transport systems, accurate representation of passenger service processes at bus stops shared by multiple operators has become increasingly important. This study develops and validates a microscopic model of passenger boarding and alighting at bus stops characterized by unstructured service patterns, diverse vehicle fleets, and irregular stopping positions. The approach focuses on individual passenger movements, enabling modeling of walking times from different waiting positions and assessing how passenger distribution and bus stopping positions affect total dwell time. Variables describing the boarding and alighting process, including waiting position, vehicle stopping position, individual boarding and alighting times, and passenger walking speed, were modeled as random variables following theoretical distributions (beta, logistic, log-normal, and normal). Bayesian estimation and bootstrap methods were applied to assess parameter stability and model fit. Field studies were conducted in two Polish cities (Kraków and Kielce) at 18 high-interference bus stop locations. Results indicate that the proposed probabilistic modeling approach enhances the accuracy of passenger flow representation and supports analysis of the effects of passenger dispersion and bus stopping position on service efficiency. The developed model can be used in microsimulation of bus stop operations, transport infrastructure design, and decision-making by transport management authorities.
1. Introduction
This section outlines the European policy and operational context of bus stop performance, reviews prior work on passenger service and dwell time modeling, identifies the research gap for shared and unregulated stops, and formulates the aim and hypotheses of the study.
1.1. Background and Significance in the European Context
With the growing problem of urban traffic congestion in European cities, public transport plays a crucial role in ensuring sustainable mobility and efficient functioning of urban systems. The operational efficiency of public transport systems depends not only on route configuration but also on the performance of bus stops as critical service nodes. A high standard of service, punctuality, and the quality of bus stop infrastructure directly influence the competitiveness of this mode of mobility compared to private transport. Efficiently managed public transport helps mitigate the negative impacts of road network use, including air pollution, noise, and congestion, contributing to improved urban livability and environmental quality [1,2]. Maintaining high public transport ridership in the European Union largely depends on user satisfaction and overall service quality [3,4].
European strategic documents, including the EU Urban Mobility Framework [5], the Sustainable and Smart Mobility Strategy [6], and the CIVITAS Initiative and SUMP 2.0 Guidelines [7], emphasize improvements in punctuality, reliability, and passenger service efficiency in bus transport systems. Particular attention is paid to minimizing operational delays at bus stops, as they constitute a critical component of total travel time and directly affect the perceived quality of urban transport. Accordingly, passenger boarding and alighting processes play a key role in bus system performance.
In Central and Eastern European countries, including Poland, the Czech Republic, Slovakia, Romania, Hungary, and the Baltic States (Lithuania, Latvia, and Estonia), bus transport plays a particularly important role in meeting urban and regional mobility needs. As a result of economic transformation and deregulation of public transport in the 1990s, a mixed system of public and private operators emerged [8,9,10,11,12]. Structural changes in regional public transport throughout Europe have led to increased diversification of organizational models and service quality [13]. Consequently, many cities operate shared-use bus stops served by various types of operators, including urban, private, and regional operators. These stops are also frequently used by taxis and unauthorized vehicles, which generates substantial disruptions to passenger service and traffic flow. In this study, a high level of traffic disruption is understood as the frequent occurrence of blocking, forced stopping, delayed departures, and irregular vehicle positioning at shared-use bus stops, resulting from interactions between multiple transport operators, general traffic, and unauthorized vehicles.
1.2. Characteristics and Significance of Bus Dwell Time
Bus dwell time is one of the key components of total travel time. It includes not only the time required for passengers to board and alight, but also the technical time associated with door opening and closing, ensuring departure readiness, and the time lost when reentering the traffic stream [14]. Dwell time directly affects system capacity, punctuality, and operational costs [15,16]. Recent simulation-based studies have further highlighted the importance of accurately modeling dwell time when evaluating the operational capacity of bus stops, particularly under connected and automated vehicle (CAV) environments [17].
Numerous studies have analyzed the factors influencing bus dwell time, such as the number of boarding and alighting, vehicle type, number of doors, passenger load, payment method and weather conditions [15,18,19,20,21,22,23,24]. These studies have shown that dwell time distributions are typically asymmetric and can be described using skewed probability distributions such as log-normal, inverse Gaussian, Fisk (log-logistic), or Johnson’s SU distributions [25,26,27]. Comparable considerations of dwell time variability as an operational parameter were also included in stop-skipping and signal coordination optimization studies [28,29]. In many existing models, dwell time is treated as a homogeneous random variable without decomposition into its component processes, which limits the precision of process representation, particularly under disturbed operating conditions or when heterogeneous vehicle fleets are involved. Furthermore, previous research has rarely accounted for variations in passenger service efficiency resulting from the presence of various operator groups that share the same bus stop, even in studies considering mixed service structures [30].
In classical modeling approaches [16,18,31] passenger boarding and alighting times were typically modeled using regression analysis based on the number of boarding and alighting passengers, with additional adjustments for the number of doors, vehicle occupancy, floor height, and method of payment method. Passenger service times have also been explicitly modeled using distribution-based approaches supported by empirical measurements [23]. Bie et al. [32] demonstrated the influence of passenger crowding on dwell time, while Novales et al. [33] analyzed the impact of weather conditions (e.g., rain) on the so-called “boarding lost time.” Several studies indicate that bus dwell time can be modeled probabilistically, as its significant variability arises from the complex interactions between vehicles, passengers, and traffic conditions in the bus stop area [15,34,35]. In recent years, a growing number of studies have incorporated more complex relationships and used data from Automatic Passenger Counting (APC) systems, Automatic Vehicle Location (AVL) systems, and statistical analyses of dwell time distributions [26]. Modeling of passenger boarding and alighting processes, as well as total dwell time, should consider not only the expected value of dwell time, but also its distribution and variability. High variability increases uncertainty in timetable planning and contributes to bus bunching and service irregularity [36]. More recent studies [37,38] have introduced Bayesian approaches and advanced probabilistic models to dwell time analysis; however, these models still generally assume homogeneous fleets and structured passenger service systems.
1.3. Research Gap in the Modeling of Shared and Unregulated Bus Stops
Previous studies [15,18,20,21,39,40] have mainly focused on bus stops served by a single homogeneous operator, assuming an orderly berth utilization system (FIFO/NO/LO/FO) and a fixed number of berths. In these studies, the maximum number of berths was limited to three, and the distances between vehicles were regular and predefined.
In actual operating conditions, there exist shared-use bus stops served by various operators and users, including urban, regional, and private operators, as well as unauthorized vehicles such as taxis. These stops are characterized by vehicle heterogeneity, irregular inter-vehicle spacing, variable stopping positions, and dispersed passenger distribution along the platform, which in practice can create up to eight operational “service channels” even at formally two- or three-berth stops. The boarding system at such stops is unregulated and vehicle positioning is largely random. These phenomena are not adequately reflected in existing models [25,27,40,41,42]. Available microsimulation tools (e.g., PTV Vissim v. 2024, Aimsun Next v.23) typically assume organized vehicle behavior, a fixed number of berths, and constant intervehicle distances, making them inadequate for analyzing the operational performance of shared and unregulated bus stops.
1.4. Comparison of the State of Research and the Scope of This Study
Table 1 summarizes the differences between the dominant research approaches reported in the literature and the methodology adopted in this study, highlighting the novel aspects of the analyses carried out.
In this study, three primary user groups are distinguished: (1) the urban operator, (2) suburban operator, and (3) taxis and other vehicles. In several statistical analyses, groups (2) and (3) exhibited similar operational behavior and were therefore jointly analyzed as a combined category referred to as other users. In all subsequent analyses, the term other users refers exclusively to this merged group.
Most identified studies focus predominantly on urban bus systems operating under an ordered service regime with homogeneous vehicle fleets. Only a few publications (e.g., [43], addressing the shared-use of bus platforms by buses and delivery vehicles while maintaining bus priority) refer indirectly to the concept of shared-use bus stops, although within an entirely different functional context.
While previous studies focused on capacity [17], operational optimization and control strategies [28,44], and bus bunching phenomena [36], the present study analyzes boarding and alighting positions, as well as stop-level interactions under multi-operator shared-stop conditions [30].
Table 1.
Comparison between previous state-of-the-art studies and the present research.
Recent research does not address the complex operating conditions of shared and unregulated bus stops, which are characterized by heterogeneous fleets, irregular stopping distances from the platform head and between vehicles, varying numbers of service channels, as well as the presence of taxis and unauthorized vehicles and dispersed passenger distribution. These previously unaccounted-for factors constitute the basis for the novel approach presented in this study, which integrates a vehicle stopping position choice model, a passenger dispersion model, proprietary probability distribution fitting, and microscale modeling of passenger walking and boarding/alighting processes.
1.5. Aim and Novelty of the Study
The passenger–vehicle interaction process during boarding and alighting is a key determinant for reliable modeling of bus stop operations. The aim of this study is to develop and validate a microscale model of passenger boarding and alighting at shared-use bus stops, accounting for heterogeneous vehicle fleets, multiple operators, variable stopping positions, and dispersed passenger distribution along the platform. The model represents a partial component of a comprehensive simulation framework for bus stop operations developed by the author. The proposed approach combines empirical analysis with computer-based microsimulation. Unlike existing commercial tools (e.g., PTV Vissim), the model allows for stochastic positioning of both vehicles and passengers within the bus stop area, enabling the dynamic representation of their interactions. Within this research, the following hypotheses were formulated:
- Due to significant differences in passenger boarding and alighting efficiency between urban bus operator vehicles and those of other operators, the models describing bus stopping position choice and passenger service are expected to differ between these user groups;
- Passenger boarding and alighting times at shared-use bus stops, served by various operators and users, should be modeled differently than at stops operated by a single, homogeneous operator group, due to the observed disturbances in traffic flow and passenger service processes;
- Considering the diversity of vehicle fleets (minibuses, midibuses, standard buses) and local traffic conditions at the stop allows for more reliable estimation of dwell times than models based on homogeneous fleets.
In the present analysis, the passenger service process was not idealized as orderly or homogeneous. Instead, bus stops were intentionally modeled as shared-use environments involving multiple operators and vehicles with differing operational characteristics. These stops exhibit inherently irregular, multichannel, and dynamic berth occupancy patterns, leading to substantial service disruptions and passenger dispersion.
The proposed model is based on a microscale, passenger-by-passenger analysis and incorporates proprietary data transformation algorithms (cut, squash, concentrate) for fitting passenger position distributions along the platform. Estimation procedures used both the maximum likelihood estimation (MLE) method and the Anderson–Darling-based MGF(AD) measure, allowing a more precise distribution fitting within the 0–1 range for variables describing passenger dispersion.
The model also reproduces delayed passenger arrivals at buses from different waiting positions, variable pedestrian walking speeds, and boarding/alighting sequences adapted to the operational practices of specific operators (e.g., intercity buses with single-door layouts). Furthermore, it simulates driver behavior dependent on local stop conditions. The vehicle stopping position was modeled as a variable related to the centroid of the waiting passenger group and the parameters of the traffic situation behind the bus, which directly affect the selection of the stopping position and total dwell time.
This aspect is largely absent from the existing literature and is of particular relevance for shared-use and unregulated bus stops.
The results of the analyses can be applied to the design and management of shared-use bus stops in cities with geometric, fleet, and traffic characteristics similar to those found in Central and Eastern European countries, as well as in regions exhibiting a high diversity of operators. The applied probability distribution fitting methods can also be transferred to models developed for other geographical contexts and operational conditions.
2. Data and Methods
This section describes the field survey sites and video-based measurement procedures, defines the variables extracted from the observations, and summarizes the statistical and simulation methods used for probability distribution fitting, regression modeling, and model validation.
2.1. Measurement Procedures
The analyses presented in this study were based on field surveys conducted in two Polish cities, Kraków and Kielce, at selected bus stops characterized by a high level of service disturbances and a diverse intensity of passenger demand. A total of 18 research sites were selected for analysis (Kraków: KRAK-01–KRAK-09; Kielce: KIEL-01–KIEL-10).
In this study, three user groups were distinguished: (1) the urban operator, (2) suburban operators, and (3) taxis and other vehicles. Because suburban operators and taxis/other vehicles displayed similar operational behavior in several analyses, groups (2) and (3) were combined into a single analytical category referred to as other users. This combined category includes:
- Suburban and regional operators (private companies providing suburban, intercity, and international services using minibuses, midibuses, and long-distance coaches);
- Intercity operators;
- Taxis;
- Other vehicles that stop within the bus stop zone, such as passenger cars, delivery vans, police vehicles, and various service vehicles.
Figure 1 presents a general illustration of the passenger service process, based on an observed traffic situation recorded during field studies at a shared-use bus stop jointly utilized by multiple operators and users.
Figure 1.
Illustration of the passenger boarding and alighting process at a bus stop shared by various operators and user groups.
In this study, an approach that focuses on the individual movement of passengers was adopted. This approach is essential for describing the operation of bus stops with a deregulated passenger service system, where vehicles stop at varying distances from each other and from the head of the platform, and passengers often wait in a highly dispersed spatial pattern. Moreover, this method allows for an accurate representation of walking delays, that is, the time required for passengers to reach the buses from more distant waiting positions.
2.1.1. Characteristics of the Surveyed Bus Stops and Traffic Disturbances
The analysis included bus stops located at both the approaches and exits of intersections, as well as those located a distance from intersection. The bus stops represented various types of infrastructure and traffic organization, from bus bays with a dedicated bus lane to stops located directly in general-purpose traffic lanes. All were located along dual-carriageway streets with at least two lanes in each direction. Designated bus bays or auxiliary lanes had platform lengths sufficient to accommodate at least two vehicles that stopped simultaneously.
At most of the stops analyzed, complex interactions were observed between vehicles operated by various operators (urban transport, private operators, suburban services, and taxis) and general traffic, which constituted an important context for the microscale analysis.
A total of approximately 118,000 vehicle movements within bus stop areas were recorded, including approximately 7000 bus stops, corresponding to more than 400,000 registered traffic events of various types. The average hourly number of services provided by the urban operator’s buses ranged from 12 to 50 buses per hour, while for private and suburban operators (including PKS) it ranged from 18 to 84 buses per hour. In addition, bus stops were occasionally used by taxis and other vehicles, with stopping frequencies reaching up to 11 vehicles per hour. Some bus stops were located directly on general-purpose lanes, which resulted in a high intensity of non-passenger-related traffic (up to 217 vehicles per hour). On the contrary, at stops with bus bays or dedicated lanes, the average value was around 74 vehicles per hour.
The average hourly passenger boarding rates for the urban operator ranged from 31 to 441 passengers per hour in Kraków and from 31 to 192 passengers per hour in Kielce. For alighting passengers, the respective values were between 162 and 384 passengers per hour in Kraków and between 31 and 163 passengers per hour in Kielce.
For stops KRAK-01–KRAK-05 and KIEL-06–KIEL-10, where suburban operators dominated and buses departed from the city, the average hourly boarding rate ranged from 18 to 232 passengers per hour, while for other stops it did not exceed 9 passengers per hour.
At stops KRAK-06–KRAK-09 and KIEL-01–KIEL-05, where suburban operators arriving in the city prevailed, the hourly alighting rates ranged from 36 to 310 passengers per hour. The volumes handled by taxis and other vehicles ranged from 0 to 3 passengers per hour for boarding and from 0 to 11 passengers per hour for alighting.
For the purposes of this analysis, traffic disruption was operationalized as the occurrence of measurable disturbance events at shared-use bus stops. These included bus entry and exit blocking, forced stopping outside designated service zones, delayed departures, and irregular vehicle positioning caused by interactions between public transport vehicles, general traffic, and unauthorized vehicles. A detailed typology and classification of disturbance events is provided in a companion paper [51].
Among all surveyed locations, the highest level of traffic disruption was recorded at stop KRAK-01, located at the end of a dedicated bus lane. At this site, an average of approximately 220 vehicles per hour were affected by traffic disturbance events during peak periods. Of these, about 164 cases per hour concerned vehicles on adjacent traffic lanes and at the nearby intersection, including taxis and vehicles performing turning maneuvers. The remaining approximately 56 cases per hour involved urban and suburban buses serving passengers. These vehicles experienced blocking during entry to the stopping area, blocking during departure from the stop, or forced stopping outside the designated service zone. At this stop, disturbances on the adjacent traffic lane affected approximately 15% of all vehicles using that lane. Among urban buses, about 27% experienced additional time losses due to entry blocking and a further 27% due to exit blocking. In the case of suburban buses, approximately 16% were affected by entry blocking and about 32% by exit blocking.
Field observations further indicated that the probability and intensity of traffic disruption increase with growing volumes of buses, boarding and alighting passengers, and non-passenger-related traffic in the vicinity of the bus stop. The share of suburban and intercity operators was identified as a key determinant of disturbance severity.
2.1.2. Measurement Methodology
Field measurements were made using a video recording technique to ensure high temporal and spatial accuracy. Each survey team operated three digital cameras, positioned to capture the entire passenger service at the bus stop and its surrounding traffic environment. In cases where several vehicles served passengers simultaneously, the process was recorded using two cameras concurrently. Measurements were made on weekdays (Monday–Friday) during morning or afternoon peak hours. The total observation time amounted to approximately 85 h.
The event times were read with an accuracy of ±0.1 s, and in cases of increased traffic intensity, with an accuracy of ±0.5 s. The video material was analyzed multiple times using Sony Vegas Movie Studio Platinum 12.0 software, which allowed synchronization and simultaneous viewing of multiple camera perspectives (Figure 2).
Figure 2.
Screenshot from Movie Studio software (v. 12.0): (a) Analyzed cross section upstream of the bus stop (time: 14:11:52); (b) View of the bus stop during the passenger boarding and alighting process (time: 14:12:01); (c,d) Analyzed cross section downstream of the bus stop (times: 14:12:48 and 14:13:05).
2.1.3. Characteristics of Recorded Public Transport Vehicles
The measurement database distinguished 24 types of vehicles operated by private suburban operators, with lengths ranging from 5.8 to 13.0 m. The seats in these vehicles varied between 17 and 50 seats. Although they were not designed to carry standing passengers, the number of people traveling in this way ranged from 8 to 20 per vehicle. Vehicles equipped with automatic doors were also identified, as this feature influenced the dynamics of the passenger boarding and alighting process.
For buses operated by the urban operator, three capacity categories were defined:
- Small capacity—with nominal capacities up to 50 passengers;
- Medium capacity—with nominal capacities between 50 and 115 passengers;
- High capacity—with nominal capacities exceeding 115 passengers.
Additionally, based on floor height at the door area, vehicles were classified as high or low-entry, which is relevant for analyzing passenger service ergonomics and dwell time. During field measurements, a total of 5953 passenger boarding and alighting times were recorded, of which 2171 corresponded to the urban operator, 3399 to suburban operators, and 383 to taxis and other passenger-serving vehicles.
2.2. Measurement Data
The measurement data include a set of quantitative and qualitative parameters that describe the operation of bus stops under real-world conditions. The data were obtained from video analysis and supplemented with geometric measurements necessary for the present analyzes and, ultimately, for the development of a comprehensive microsimulation model of bus stop operation.
Data were stored in a structured database that included both primary events and variables (directly extracted from video recordings) and derived variables. The recorded events and parameters included, among others:
- Moment of the bus stopping;
- Start and end of the passenger boarding and alighting;
- Door opening and closing times;
- Vehicle stopping positions at the bus stop;
- Sequence and timing of vehicle arrivals and departures;
- Passenger waiting positions relative to the head of the platform;
- Numbers of boarding and alighting passengers;
- Individual boarding and alighting times per passenger;
- Start and end moments of passenger service;
- Operational and technical dwell durations;
- Moment of departure from the stop;
- Delay times resulting from traffic disturbances;
- Reactions of other traffic participants (lane changes, stops, bypass maneuvers).
This data structure enables a statistical analysis of bus stop performance parameters and the development of microsimulation models of passenger boarding and alighting processes, including the analysis of disturbances caused by the simultaneous service of multiple vehicles and various operator types.
In this study, the analysis focused on the most relevant parameters from the perspective of modeling passenger boarding and alighting times at shared-use bus stops, namely:
- xp—passenger waiting position along the platform, measured relative to the reference cross section at 0 meters (bus stop head) (m);
- Pz1—stopping position of the bus/vehicle at the first boarding position, measured relative to the reference cross section at 0 meters (bus stop head);
- Vpas—passenger walking speed (m/s);
- tb—individual passenger boarding time (s/pass);
- ta—individual passenger alighting time (s/pass).
The spatial distribution of passengers waiting at the bus stop significantly influences the service process, including vehicle stopping positions, passenger walking time to the vehicle, and the decision for initiating passenger service for a given bus. Each passenger who boarded a bus or other vehicle during the observation period was individually analyzed. The positions were determined for the moment before the start of their walking movement toward the vehicle. An example of passenger distribution at a shared-use bus stop served by various operators is shown in Figure 3a, while the stopping of a suburban minibus at the first boarding position, located a considerable distance from the bus stop head, is shown in Figure 3b.
Figure 3.
Examples of bus stops: (a) High dispersion of waiting passengers at the stop; (b) A regional operator’s minibus stopping at the first boarding position, located at a large distance from the bus stop head.
Buses stop at highly variable distances, both between vehicles and relative to the platform head. This variability significantly disrupts the passenger service process and increases operational uncertainty.
The stopping positions were determined through repeated analysis of video recordings collected at the studied bus stops. These positions were referenced to characteristic field-inventoried elements of the bus stop infrastructure, taking into account the known lengths of the vehicles. The method used to determine the variables describing the waiting positions along the platform (xp), the centroid of the passenger group () and the vehicle stopping position of the vehicle (Pz1) is illustrated in Figure 4. The beginning of the bus stop (cross section at 0 m), relative to which the stopping positions of vehicles were estimated, was defined as:
Figure 4.
Illustration of the method to determine the head of the bus stop (0 m cross section), vehicle stopping position Pz1 and average position of the passenger waiting group: (a) In a bus bay; (b) On an additional traffic lane with marked bus stop line; (c) On an additional traffic lane without markings. The legend is consistent with Figure 1.
- For bus bays, the beginning of the stopping section of the bay, measured from the departure side (Figure 4a);
Due to the diversity of bus stop types (in bays, in general-purpose lanes, and on dedicated bus lanes) and variations in their geometric parameters, shelter locations, and passenger seating arrangements, the stopping positions of vehicles relative to the head of the platform vary considerably. As a common reference point, the average position of the group of waiting passengers was adopted. This parameter is characteristic for each bus stop, reflecting its operational specifics and passenger load. The variable analyzed in this study was determined relative to this reference according to the following formula:
where
- Pp1—position of the vehicle stopping point at the first passenger service position, calculated relative to the average position of the waiting passenger group (m);
- Pz1—position of the vehicle stopping point at the first passenger service position, measured relative to the 0 meters cross section at the head of the stop (m);
- —average position of the waiting passenger group at the bus stop, measured relative to the 0 meters cross section (m).
The considerable variation observed in the stopping positions of buses at stops, particularly in the case of other users, indicates the need to identify the factors that influence this behavior.
To estimate, for the purposes of passenger service modeling, the individual boarding and alighting times per passenger, the beginning and end of these processes were recorded separately. The examples of ‘intensive’ boarding and alighting—where passengers remained on board or alighted continuously without time gaps. In the cases where passengers approached the vehicle from greater distances or exited the bus with a delay relative to others, their start and end moments were recorded as separate events.
2.3. Methods of Statistical and Simulation Analysis
The parameters of the components of the bus stop simulation model were determined using methods of probability theory and mathematical statistics, including descriptive analysis, mean values, analysis of variance, correlation and regression analysis, and numerical procedures.
For statistical computations and analyses, the following software tools were used: Python (v. 3.x), SAS (v. 9.4), R (v. 4.x), Microsoft Excel (v. 2019/365), and others.
To develop the simulation model of bus stop operation, a dedicated computer program was written in the Python programming language.
2.3.1. Analysis of Fitting Parameters of Theoretical Distributions
The fitting of probability density functions to empirical distributions was carried out in two groups, separately for passengers of the urban operator and for other users. The analyzes were performed using the fitdistrplus package in the R environment. The following continuous theoretical distributions were tested: beta, gamma, normal, log-normal, exponential, logistic, and Weibull. The problem of distribution fitting was treated as an optimization task, consisting of finding such a combination of parameters that maximizes a selected goodness-of-fit measure computed for the empirical data set.
Among all possible measures of fit quality, two were selected:
- Likelihood function—Maximum Likelihood Estimation (MLE);
- Anderson–Darling statistic—Maximum Goodness-of-Fit estimator (MGF(AD)).
The log-likelihood function represents the fundamental measure of distribution fit quality and is the only one for which analytical maximizing solutions exist (for all distributions considered in this study). The optimization that maximizes this function is known as MLE (Maximum Likelihood Estimation), providing the most likely parameter estimates for a theoretical distribution.
The Anderson–Darling (AD) statistic, similar to the Kolmogorov–Smirnov statistic, is calculated on the cumulative distribution function of the empirical data. Like the likelihood function, it does not depend on histogram binning. The smaller the AD statistic, the better the fit. Given that the Cramér–von Mises test is based on the AD statistic, its use as an optimization target is natural. Since no analytical solutions are available that minimize the AD statistic for an arbitrarily data sets, solutions were sought using general optimization algorithms. In this study, the Nelder–Mead algorithm [52] was used. To minimize the AD estimator, the Maximum Goodness-of-Fit estimator (MGF), denoted as MGF(AD) in this paper. Similar probabilistic optimization strategies, including empirical Bayes estimation, have been successfully implemented in urban traffic safety modeling to identify the best-fitting stochastic relationships [53].
When the empirical data set contained values outside the domain of the theoretical distribution, data transformations were applied. Numerical fitting procedures require no observations lie at the domain boundaries. This is particularly relevant when fitting distributions defined over the range (0, 1), such as the beta distribution. Because transforming the dataset to fit within the required domain is not a unique operation, three original algorithms were developed and applied:
- Cut—removes data points lying outside the domain or at its boundaries; a simple and conservative method;
- Squash—applies a linear ‘compression’ transformation that slightly shifts data values while ensuring that all values fall within the allowable domain;
- Concentrate—modifies only the values outside the domain while preserving the order of observations (e.g., the smallest value before transformation remains the smallest afterward).
Squash transformation produces a closed data range, while optimization algorithms require an open domain; therefore, a positive “margin” parameter (set arbitrarily to 0.01) was used to slightly shrink the transformed range. This linear transformation preserves proportional distances between observations.
When fitting one-dimensional distributions of the variable describing passenger waiting positions xp to empirical data, three transformations were applied:
- Cut(0.05)—values outside the domain extended by 0.05 were removed;
- Squash(0.01)—when the observed range exceeded the allowed range, a linear compression with a 0.01 margin was applied;
- Concentrate(0.01; 0.001)—extreme values were shifted to satisfy the following conditions:
- ○
- Each observation was shifted minimally;
- ○
- All values were contained within the allowed domain extended by 0.01;
- ○
- After transformation, the distance between neighboring values remained at least 0.001;
- ○
- The order of the empirical data were preserved.
The statistical significance of the fitted distributions was evaluated using the Cramér–von Mises test based on the Anderson–Darling statistic (AD). This combination is recognized as one of the most powerful tests, particularly stronger than the Kolmogorov–Smirnov test [54]. The test became computationally feasible after the development of an efficient method for calculating the cumulative distribution function of the AD statistic under the null hypothesis [55]. The significance of other distributions was obtained by transforming the dataset to achieve a uniform distribution under the null hypothesis. The results of the fitted distribution variants were ranked according to the AD goodness-of-fit measure. The cases in which the null hypothesis (that the data set originates from the tested distribution) could be rejected at α = 0.05 were identified. Homogeneous groups of distributions (i.e., those not significantly less well fitted according to the AD statistic) were also established.
To estimate the variability of the fit quality, bootstrap resampling analysis was performed for each fit attempt. Since for estimated quantities (AD statistic and distribution parameters), about 200 simulations are sufficient to achieve satisfactory estimates [48], 2001 bootstrap replications were performed. This allowed statistical differences between each pair of samples to be assessed in terms of Anderson–Darling distance using a non-parametric significance test. The test statistic was derived from the empirical distribution of the fit quality obtained through bootstrap analysis. Bootstrap methods belong to the class of simulation techniques in which statistical inference is based on repeatedly generated samples from the same dataset according to defined distributions.
2.3.2. Significance Analysis of Factors Affecting the Stopping Position of the First Vehicle at the Bus Stop
For each variable whose influence on stopping position could have significant implications for the study, a series of basic statistical tests was performed using the R software environment [56]. The objective was to verify whether there was a statistically significant relationship between each tested variable and the position Pp1 that represents he stopping position of vehicles in the first passenger service position. The results of these analyzes were used to identify the factors to be included in the multiple regression analysis.
Depending on the type of variable, one of the following statistical tests was applied:
- For quantitative variables, the Pearson correlation coefficient significance test was used;
- For dichotomous variables, Student’s t-test was applied;
- For nominal variables, a one-way analysis of variance was conducted.
2.3.3. Multiple Regression Analysis for the Variable Representing the Stopping Position of the First Vehicle at the Bus Stop
Multiple regression analysis was applied to develop an optimal model that simultaneously provides a good explanation of the dependent variable while maintaining parsimony, that is, consisting of as few explanatory variables as possible. Several approaches exist to balance these two criteria. In this study, the model was selected based on the minimization of the Bayesian Information Criterion (BIC), which originates from Bayesian statistics and estimates the maximum closeness of the theoretical model to the true model [57,58]. The BIC effectively balances model fit and simplicity: it favors models with higher explanatory power for the dependent variable and fewer independent variables. Compared to the commonly used adjusted coefficient of determination (R2), BIC provides a more robust measure of model quality.
The BIC is defined as:
where
- L—maximized likelihood function value for the estimated parameter vector;
- k—number of model parameters;
- N—number of observations.
The optimal model, according to this criterion, is the one with the lowest BIC value. The search for such a model was carried out by systematically computing regressions for all possible subsets of explanatory variables using the specialized and highly optimized leaps library in the statistical environment [56]. The regression analysis procedure follows the structure illustrated in Figure 5.
Figure 5.
Flowchart of the multiple regression procedure for determining the vehicle stopping position at bus stop using the Bayesian Information Criterion (BIC).
3. Results
The results are reported in three parts. The first part presents an empirical characterization and distribution fitting of passenger waiting positions. The second part focuses on the analysis and modeling of vehicle stopping position selection at the first service point. The third part describes the development and validation of the microsimulation algorithm for passenger boarding and alighting time.
3.1. Analysis of Passenger Waiting Positions at Bus Stops
In the developed microscopic simulation model of passenger service, an individual passenger-by-passenger approach was adopted to represent movements from the platform to the bus. Individual boarding and alighting times, pedestrian walking speeds, and passenger waiting positions were modeled as random variables, each described by an appropriate theoretical probability distribution.
3.1.1. Measurement Results at the Analyzed Bus Stops
Based on field measurements, the spatial distribution of the passenger waiting areas at the analyzed bus stops was characterized (Appendix A, Table A1). Parameters describing passenger waiting position xp—such as range, mean value , standard deviation σxp and the average hourly number of boarding passengers —were estimated separately for passengers of the urban operator and for other users.
For passengers of the urban operator, the average waiting position typically corresponded to the location of the passenger shelter. Previous studies have shown that bus shelters substantially influence passenger clustering, as individuals tend to remain within or near the sheltered zone due to improved thermal comfort and perceived safety [59,60,61]. The spatial and structural characteristics of bus shelters also affect how passengers use waiting areas and influence the perceived quality of service [62]. In contrast, for other users—particularly at stops with high passenger boarding intensity—the average waiting position was located several to more than ten meters farther from the stop head (e.g., KRAK-01-KRAK-09, KIEL-08, KIEL-10).
The standard deviation of the passenger waiting positions for the urban operator ranged from 2.1 to 7.6 m. The highest value 7.6 m was observed at KIEL-08 stop, which exhibited the highest passenger load among other users (approximately 200 passengers per hour). At this location, urban transit buses operating primarily on suburban routes were observed, and the stop geometry and seating layout contributed to a high dispersion of waiting passengers. For other users in Kielce, the standard deviations were comparable to those of the urban operator, while in Kraków, at the KRAK-01 through KRAK-04, they were notably higher, between 7.5 and 14.1 m. Bus stops KRAK-02 and KRAK-04 showed the greatest passenger dispersion ( = 11.0 m and 14.1 m, respectively). This was related to high volumes and the absence of physical constraints that limit the waiting area, unlike at stops such as KRAK-05 (located near an intersection) or KRAK-01 (with a narrow sidewalk or adjacent buildings). The extent of the passenger waiting area increased proportionally with stop passenger load.
3.1.2. Fitting of Theoretical Distribution Parameters to Empirical Histograms
For the empirical distributions of passenger waiting position variable theoretical distribution parameters were estimated separately for urban operator passengers and other users at each analyzed stop. The fitting procedure considered the following continuous probability distributions: beta, gamma, normal, log-normal, exponential, logistic, and Weibull.
Due to small passenger counts and limited sample sizes for other users (typically 6–16 passengers) at stops KRAK-06–KRAK-09 and KIEL-01–KIEL-05, theoretical distribution fitting was not performed for these cases. Although the sample sizes for other users on KIEL-07 (42 passengers) and KIEL-09 (54 passengers) were also limited, analyzes were conducted for these datasets, acknowledging a higher estimation error (approximately 2 m).
Representative results of the goodness-of-fit measures for fitted theoretical distributions are shown in Table 2 for stop KIEL-06, separately for the urban operator and other users. Similar analyzes were conducted for all other locations.
Table 2.
Goodness-of-fit measures for theoretical probability distributions fitted to the empirical histogram of the passenger waiting position variable for urban operator and other users passengers at the KIEL-06.
When no differences were observed between the results of the applied algorithms (MLE, MGF(AD)), a single result was reported for a given distribution, without distinction between transformation methods (cut, squash, concentrate). To evaluate the conformity of empirical data with the fitted distribution, the calculated p-value was used. The null hypothesis that the sample originated from the tested distribution was rejected if the p-value was less than the significance level .
The cases in which the null hypothesis could be rejected at the adopted significance level are highlighted in bold. Homogeneous groups of distributions (in terms of statistical similarity) were indicated with a horizontal black line. The two best-fitting distributions (highest log-likelihood values, lowest AD statistics) were highlighted in blue (for urban operator) and green (for other users).
Among the probability distributions that best described the analyzed variable, the beta distribution appeared most frequently. For 17 of analyzed bus stops serving urban operator passengers, the beta distribution was ranked among the two best-fit distributions according to the MGF(AD) optimization method (i.e., those with the highest log-likelihood values or the lowest AD statistics). According to the MLE method, this distribution appeared at all stops for at least one of the applied data transformation methods (cut, squash, or concentrate).
For other users, the beta distribution was among the two best-fit distributions at 8 out of 9 stops, based on both the MGF(AD) and MLE methods. Among the most frequently and best-fitted distributions, the logistic distribution was also identified.
At stop KRAK-05, for other users, the null hypothesis that the data originate from the beta distribution could be rejected at a significance level of α = 0.05. For stop KRAK-04, it was not possible to identify any theoretical distribution consistent with the empirical data for other users at the same significance level (α = 0.05). In that case, the beta distribution, based on the cut-data transformation method, was still among the two best-fit distributions according to the log-likelihood measure, with probabilities of 0.03 for MGF(AD) and 0.01 for MLE.
Examples of histograms together with fitted probability density functions are shown in Figure 6 for stop KRAK-03. The figure presents only those probability density functions that were consistent with the observed data set at the adopted significance level.
Figure 6.
Histograms of passenger waiting positions at the bus stop with fitted probability density functions for KRAK-03 bus stop: (a) urban operator; (b) other users.
In probability theory, the beta distribution is a continuous probability distribution with a density function defined over the interval from od do , expressed as:
where
- ;
- —bounds of the variable range;
- —shape parameters of the distribution;
- —beta function (Euler integral of the first kind).
For known interval limits from do , the mean and variance are, respectively:
The beta distribution is commonly used to model order statistics and processes characterized by natural lower and upper bounds. It is suitable for variables constrained on both sides. In the special case when α = β = 1, the beta distribution is reduced to the standard uniform distribution.
Since the beta distribution was found to be one of the best fits for describing passenger waiting positions at most of the analyzed stops, and given its mathematical properties and range of applicability, it can be effectively used in the bus stop simulation model to estimate passenger walking times to buses and vehicle stopping positions at the stop.
The examples of the parameters α and β of the beta distributions that best described the stops empirical data for the analyzed (with the ± symbol denoting the standard error of the estimated parameters obtained by bootstrap analysis) are presented in Table 3. It was assumed that the true parameter value (i.e., not estimated) lies, with a probability of 68.27% (the integral of the normal distribution density function over the range from 1 to 1), within the interval (mean standard error; mean + standard error). The same parameters were also calculated using the estimated sample means , standard deviations , and known interval bounds , , by transforming Formulas (4) and (5). The parameters obtained from these equations were found to be close to those estimated for the best-fit distributions according to the applied goodness-of-fit measures. Since they fall within the range of the standard error determined in the bootstrap analysis (with the exception of three urban operator stops: KIEL-05, KIEL-06 and KIEL-07), it was concluded that they can be estimated with sufficient precision using the above formulas for the purpose of modeling passenger boarding and alighting time, based on measured or predicted values of , , and the interval bounds (, ).
Table 3.
Summary of the beta distribution parameters for the empirical data set of the variable representing the waiting position of the urban operator at the bus stop , obtained using the MGF(AD) optimization method.
Figure 7a,b present the probability density functions of the beta distributions with the best-fit parameters for all analyzed bus stops. Figure 7a,b clearly show differences in the shapes of the distributions determined for urban operators and other users, particularly for the bus stops with higher passenger boarding volumes, i.e., from KRAK-02 to KRAK-05, as well as KIEL-08 and KIEL-10.
Figure 7.
Fitted beta distribution shapes for the passenger waiting position along KRAK-01 to KRAK-09 for two user groups: (a) bus stops in Kielce; (b) bus stops in Kraków.
On the basis of the measurement results, it was determined that in the microsimulation model representing the functioning of bus stops, the average position of the group of passengers of the urban operator, , can be assumed to correspond to the location of the center of the bus shelter. Similarly, the average position , for other users can be assumed for less loaded stops ( ≤ 100 passengers/h). In the absence of a shelter, the mean value may typically be taken as approximately 12 m.
For bus stops with heavier passenger loads ( > 100 passengers/h) the average position of the group of passengers of other users , is greater than that of the urban operator by approximately 5–20 m, depending on the average hourly volume of passengers boarding passengers for all operators:
- m dla = 101–200 passengers/h;
- m dla = 201–300 passengers/h;
- m dla = 301–350 passengers/h;
- m dla = 351–400 passengers/h.
For less loaded stops ( ≤ 100 pas/h), the spatial range of waiting positions on the platform generally falls between 15 and 25 m for both groups of operators analyzed. For more heavily loaded stops ( > 100 passengers/h), the waiting area is larger—approximately 25 to 35 m for urban operators and 30 to 50 m for other users (provided that there are no geometric constraints related to the location near intersections or buildings).
For the purposes of the simulation model, the following xp ranges may be adopted for passengers of the urban operator:
- 0–20 m for ≤ 50 passengers/h;
- 0–25 m for = 50–100 passengers/h;
- 0–30 m for = 101–200 passengers/h;
- 0–35 m for = 201–400 passengers/h,
and for other users:
- 0–20 m for ≤ 50 passengers/h;
- 0–25 m for = 50–100 passengers/h;
- 0–30 m for = 101–150 passengers/h;
- 0–35 m for = 151–200 passengers/h;
- 0–40 m for = 201–250 passengers/h;
- 0–45 m for = 251–300 passengers/h;
- 0–50 m for = 301–400 passengers/h,
Assuming that the starting point of the passenger waiting area is located as close as possible to the front of the stop, typically within 15 m from the center of the bus shelter. In cases where the available waiting area is limited (e.g., due to buildings or intersections), the range should be adjusted accordingly (reduced).
When determining the standard deviation for use in the simulation model, regression models (Figure 8) can be used to approximate how varies depending on the average volume of boarding passengers for all operators.
Figure 8.
Relationship between the average hourly volume of boarding passengers at the bus stop and the standard deviation of passenger waiting positions along the bus stop.
The correlation coefficients (r) were found to be 0.68 for the urban operator and 0.78 for other users. The corresponding p-values of 0.0013 and 0.0078 indicate that the relationships are statistically significant at the adopted significance level of α = 0.05. At the same time, it is important to account for the geometric and traffic parameters measured or predicted from the bus stop that may influence the dispersion of passenger waiting positions, such as the length of the bus bay, the location of the shelter and seating areas, the presence of nearby buildings, and the width of the sidewalk. The operational characteristics of the stop should also be considered, including the share of traffic volumes from suburban operators and other vehicles stopping at the bus stop. An increase in passenger demand and the share of suburban and intercity services was also observed to be directly associated with higher levels of traffic disruption at the stop, which indirectly affects passenger dispersion and vehicle stopping behavior.
Based on the mean value, standard deviation, and the adopted range of variability, the α and β parameters of the beta distribution (calculated from the transformed Equations (4) and (5)) will be determined in the simulation model. These parameters will be used to randomly generate the positions of individual passengers boarding buses. The parameters will be defined separately for the two user groups identified in this subsection.
3.2. Analysis of Bus and Other Vehicle Stopping Position Selection at Bus Stops
This subsection presents the statistical verification of hypotheses related to the stopping position of the first vehicle at the stop and introduces the regression-based model used to generate stopping positions in the microsimulation framework, with separate parameterization for urban operator buses and for other users.
3.2.1. Examination of the Significance of Factors Affecting the Stopping Position of the First Vehicle at the Stop
A database of vehicle stops was developed from the collected research material, allowing the identification of variables (features) for each recorded stop. These variables were included in the statistical analysis as factors influencing the position , the stopping position of buses and other vehicles at the first passenger service position at bus stops.
The following hypotheses were tested:
- There is a relationship between and the type of users (hypothesis 1);
- There is a relationship between for buses operated by the urban operator and the presence and type of vehicles following the observed vehicle (hypothesis 2);
- There is a relationship between for vehicles of other users and the presence and type of vehicles following the observed vehicle (hypothesis 3);
- There is a relationship between for buses operated by the urban operator and the number of vehicles following the observed vehicle (hypothesis 4);
- There is a relationship between for vehicles of other users and the number of vehicles following the observed vehicle (hypothesis 5);
- There is a relationship between for buses operated by the urban operator and the occurrence of passenger boarding (hypothesis 6);
- There is a relationship between for vehicles of other users and the occurrence of passenger boarding (hypothesis 7).
Table 4 presents the basic descriptive statistics of the variable divided into three user groups: urban operator, suburban operator, and taxis and other vehicles. The estimated mean values of for vehicles operated by urban and suburban operators differ only slightly (by 0.7 m). However, significant differences in the standard deviation—on the order of several meters, between the analyzed user groups at the stop were observed.
Table 4.
Descriptive statistics of the variable for the types of bus stop users.
To verify hypothesis 1, multiple comparison tests were performed, and their results are presented in Table A2 in Appendix B. The statistically significant differences identified between the group of vehicles operated by the urban operator and the group of other users (including suburban operators, taxis, and other vehicles) with respect to the variable analyzed indicate the need to consider these groups separately in further analyzes using multiple regression. During field observations at bus stops shared by various operators, the influence of the traffic situation occurring behind the approaching vehicle on driver behavior—specifically, the choice of service position—was clearly noticeable. This effect was particularly evident when another urban bus or a larger number of vehicles approached behind the analyzed vehicle.
To verify hypotheses 2 and 3, a one-way analysis of variance was performed for the independent variable. The parameters estimated from three measurement samples were compared for the following traffic situations (nominal variables S):
- At least one urban operator approaches behind the analyzed vehicle (traffic situation S1);
- Only vehicles of other users following the analyzed vehicle (traffic situation S2);
- No vehicles following the analyzed vehicle (traffic situation S3).
Table A3 (Appendix B) presents descriptive statistics of the variable by analyzed traffic situations (S). The null hypothesis assumes that there is no relationship between the variable and the traffic situation.
Based on the ANOVA performed for the entire measurement sample, it was found that there is a statistically significant relationship between the traffic situation and the service position for the urban operator (F = 20.3, p-value < 0.01) as well as for other users (F = 53.7, p-value < 0.01) at the adopted significance level of 0.01.
The results of multiple comparisons using the Tukey HSD post hoc test for the variable are presented in Table A4 (Appendix B). They indicate statistically significant differences between the estimated values for the three traffic situations analyzed for the urban operator. For other users, no significant differences were found between groups S2 and S3, while significant differences were observed for the remaining pairs of groups at the adopted significance level of 0.01.
To test Hypotheses 4 and 5, the Pearson correlation coefficient (R) was calculated to examine the relationship between the variable and the number of vehicles following the analyzed vehicle. The tests yielded statistically significant results at the significance level of 0.01. The service position shows a weak negative correlation with the variable , representing the number of vehicles following the analyzed vehicle. The higher the number , the smaller the value of for urban buses (correlation coefficient R ≤ 0.20) and for other users’ vehicles (R ≤ 0.16). A relationship of similar nature was observed for other users’ vehicles.
To examine whether there is a relationship between the service position at the first passenger service position of urban operator buses and the occurrence of passenger boarding (hypotheses 6 and 7), Student’s t-tests were conducted. The independent variable was the passenger boarding service (PSB), measured at two levels: passenger boarding and no boarding service. The null hypothesis assumed that the mean values of the variable in both groups are equal. The tests were carried out at a significance level of 0.01.
For the urban operator, no basis was found to reject the null hypothesis of equal means between the groups (Student’s t-statistic t = 0.6, p = 0.55). For other users, the analyzed groups differed significantly in mean values. In the group without passenger boarding, the mean was −13.2 m, while in the group without passenger boarding it was −6.1 m (Student’s t-statistic t = 9.3, p < 0.01).
The results of preliminary statistical analyzes aimed at identifying the characteristics of the studied sample indicated that, in further analyzes using multiple regression, it is necessary to:
- Analyze separately the group of urban operators and other users due to statistically significant differences between these groups with respect to the examined variable,
- Take into account the influence of the traffic situation (type and number of vehicles following the analyzed vehicle),
- Consider the impact of the type of passenger service (boarding service or no boarding service).
3.2.2. Multiple Regression Model for the Service Position of Buses and Other Vehicles at the Bus Stop
The analyses were carried out separately for buses operated by the urban operator and for vehicles of other users. The dependent variable is the service position of the vehicle at the bus stop for passenger service, measured relative to the position of the center of the group of waiting passengers for the corresponding user type. The analyses were based on the recorded service positions of vehicles stopping at the first passenger service position of the bus stop (variable ). These observations were made under free-choice conditions and without obstruction by other vehicles. In the comprehensive simulation model of bus stop operations, the developed regression model can be used to determine the service positions of vehicles for all berths at the bus stop. For each vehicle, regardless of the number of vehicles already stopped at preceding berths, the simulation model calculates the so-called desired service position using the same regression model. If a given vehicle cannot stop at the expected position under free-choice conditions, it moves as close as possible to the preceding vehicle, maintaining only the minimum safety distance.
Among the explanatory variables (predictors) considered in the analysis is the variable traffic situation . It is a qualitative variable with three categories that describe traffic situations (as presented in Section 3.1). To include its influence in the regression model, it was transformed into two binary variables, (S2) and (S3), which take the value 1 when a given traffic situation occurs and 0 otherwise. To avoid multicollinearity, the case in which at least one vehicle of the urban operator followed the analyzed vehicle within approximately 10 s was omitted. Consequently, two dummy variables were introduced instead of three. The complete list of explanatory variables (predictors), established based on the analysis presented in Section 3.1, is as follows:
- ZN1—passenger boarding service (PSB), where the value 1 indicates the presence of boarding passengers and 0 indicates their absence;
- ZN2—position of the center of the group of waiting passengers at the stop (m);
- ZN3—only vehicles of other users following the analyzed vehicle (traffic situation S2);
- ZN4—no vehicles following the analyzed vehicle (traffic situation S3);
- ZN5—number of vehicles following the analyzed vehicle ( (vehicle).
The diagram in Figure 9 presents the multiple regression models that best describe the service position occupied by vehicles at the bus stop during passenger service.
Figure 9.
Multiple regression models for vehicle stop position at the bus stop based on BIC values: (a) urban operator; (b) other users. Color (and the y-axis) represents the BIC; darker colors indicate lower (better fit) BIC values.
The color and the Y-axis represent the BIC. Each horizontal segment of the plot corresponds to a separate regression model. The presence of a rectangle indicates the inclusion of a given independent variable (marked on the horizontal axis) in the model. The lower its value (the darker the color), the better the fit of the model.
For the urban operator, the model with the lowest criterion value (BIC = −34) includes the explanatory variables ZN2, ZN3, and ZN5. For other users, the best model also includes variable ZN1 (BIC = −220). Since the variables ZN3 and ZN4 describe the influence of traffic situation on the position of the occupied service, both should be considered in the developed model.
Partial regression plots are used to visualize the effect of an individual independent variable in a multiple linear regression model, accounting for its collinearity with other predictors. A simple scatter plot of X and Y is not suitable for visualizing such relationships because it does not consider the remaining variables included in the model. In particular, the actual contribution of a predictor to the model’s explained variance, as observed in a scatter plot, is smaller: The more collinear the predictor is with other independent variables, the weaker this relationship appears.
Within the identified model, the significance of each predictor was calculated while accounting for the effects of all other predictors. To assess how much each independent variable truly contributes to the model, recognizing that other predictors may reduce its apparent strength compared to a simple correlation, partial regression plots were generated. Figure 10 and Figure 11 present these plots, showing the influence of individual observations on the estimated regression coefficients. Only residuals for the variables ultimately included in the final model are shown.
Figure 10.
Partial regression plots illustrating the influence of variables included in the multiple regression model on the regression residuals for vehicle stopping position for the urban operator: (a) ZN2—average position of the passenger group on the platform ; (b) ZN3—following vehicles of other users only (traffic situation S2); (c) ZN4—no following vehicles (traffic situation S3); (d) ZN5—number of following vehicles ().
Figure 11.
Partial regression plots illustrating the influence of variables included in the multiple regression model on the regression residuals for vehicle stopping position for other users: (a) ZN1—boarding passengers, (b) ZN2—average position of the passenger group on the bus stop platform ; (c) ZN3—only vehicles of other users following the analyzed vehicle (traffic situation S1), (d) ZN4—no vehicles following the analyzed vehicle (traffic situation S2), (e) ZN5—number of vehicles following the analyzed vehicle ().
A partial regression plot is defined as a scatter plot of the following variables:
- Instead of the independent variable X, the residuals from regressing this variable on all other independent variables in the model;
- Instead of the dependent variable Y, the residuals from regressing the dependent variable on all independent variables except the selected X.
This construction has the following properties:
- The correlation coefficient between the plotted variables is equal to the standardized multiple regression coefficient β associated with variable X;
- The slope and intercept of the fitted linear trend are identical to those of the corresponding multiple regression equation;
- The plot allows detection of regression assumption issues such as heteroscedasticity (variance of Y depending on the predictor) or nonlinearity.
On the basis of the partial regression plots presented in Figure 10 and Figure 11, it can be concluded that the assumption of homoscedasticity is satisfied. The prediction error of the dependent variable does not depend on the values of the predictors and remains constant. No evident non-linearity of the relationship is observed, which indicates that the adopted regression assumptions have been met.
The basic parameters of the regression model for the stopping position of vehicles at the bus stop of the urban operator are summarized in Table 5, while the corresponding parameters for other users are presented in Table 6.
Table 5.
Summary of the regression model parameters for the vehicle stopping position at the bus stop of the urban operator.
Table 6.
Summary of the parameters of the regression model for the vehicle stopping position of the vehicle at the bus stop for the other users.
The multiple regression models and their coefficients are statistically significant at the adopted significance level of 0.01. The application of the above procedure to adjust the position of the bus relative to the centroid of waiting passengers at the stop reduces the variance of the prediction error by 7% for the urban operator and by 26% for other users.
The multiple regression models that can be used to calculate the stopping position are presented in Table 7.
Table 7.
Multiple linear regression models to calculate the stopping position of the vehicle at the bus stop.
Although the influence of variable ZN2 is not significant in terms of the estimated stopping position, it is included in the model due to the need to reference the location of the bus stop head, expressed in meters, relative to the centroid of the group of passengers waiting at the stop. A strong effect is observed for the variable ZN5, which represents the number of vehicles following the analyzed vehicle belonging to other users. When three vehicles following, the stopping position may shift towards the front of the stop by approximately 10 meters compared to the situation when no vehicles approach. This is consistent with field observations indicating that drivers consider whether they can stop as close as possible to boarding passengers or must move closer to the stop head due to traffic situations (a large number of vehicles waiting to enter the stop, potentially blocking it). In such cases, the passenger walking time to the bus often increases, hence the need to include this variable that affects the choice of the vehicle stopping position.
Low R2 values and large standard errors indicate that the regression equation explains only a small portion of the variability of the dependent variable . Therefore, its value is primarily influenced by random factors and possibly other deterministic factors not included in the model. Due to the strong influence of randomness, the stop position of vehicles for passenger boarding and alighting in the bus stop simulation model should be sampled from a normal distribution with a mean calculated from the multiple regression models and a standard deviation as given in Table 7. This distribution will be truncated on both sides according to the spatial constraints of a given stop related to where vehicles can stop for passenger service. A well-constructed model should be characterized by regression residuals of the stopping position that follow a normal distribution after accounting for the above predictors. These residuals are shown in Figure 12 with a fitted normal distribution, while Figure 13 presents the corresponding quantile–quantile (Q–Q) plots, where the theoretical distribution is normal.
Figure 12.
Histograms of residuals for vehicle stopping position with fitted normal distribution: (a) urban operator; (b) other users.
Figure 13.
Q-Q plots: (a) urban operator; (b) other users.
The shape of the normal probability density function shown in Figure 12 is close to the theoretical distribution.
In Figure 13, the points on the plot lie close to the straight line and are evenly distributed on both sides, indicating that the data come from a normal distribution.
3.3. Simulation Model for Calculating Boarding and Alighting Time
This subsection introduces the microsimulation model of the passenger boarding and alighting process. It first summarizes the event-based algorithm, then specifies the probability distributions and parameter estimation for unit service times and passenger walking speeds, and finally validates simulated total boarding and alighting times against the collected field data.
3.3.1. Description of the Algorithm for Calculating Boarding and Alighting Time
The algorithm developed in this study, which simulates the passenger service at bus stops, is based on sequentially computing individual events related to the boarding and alighting of passengers from a given vehicle. The input data for the simulation of the boarding and alighting time are a passenger list, where each passenger is assigned an arrival time at the vehicle determined by their walking time. This time results from randomly generated variables: the passenger’s waiting position at the stop, their walking speed, and the stopping position of the vehicle at the stop. For each passenger, individual boarding and alighting times are estimated. The simulation output data include the moment when the last passenger boards the vehicle and the total boarding and alighting time. A dedicated computer program developed in the Python programming language was used to construct the bus stop operation simulation model and to analyze its interaction with general traffic. One of its components is a sub model designed to simulate boarding and alighting times.
Executing the simulation stages of alighting and boarding enables the determination of the total boarding and alighting time. A general block diagram of the simulation of the boarding and alighting process is presented in Figure 14. A detailed flow chart of the algorithm to calculate boarding and alighting time, implemented in programming form and divided into individual functional blocks, is provided in Appendix C (Figure A1, Figure A2 and Figure A3).
Figure 14.
General flow chart of the simulation process for passenger boarding and alighting.
It was assumed that the boarding and alighting process begins, in the absence of alighting passengers, at the moment when the first passenger reaches the vehicle. At the same time, for buses equipped with automatically operated doors, it was assumed that passenger service cannot start more than two seconds after the vehicle stops at the bus stop (a value determined based on field measurements), even if the first passenger’s walking time is shorter.
Based on the randomly generated waiting position of the passenger and their walking speed , the walking time to the bus or other vehicle is calculated. When there are several boarding passengers, they form a queue to enter the vehicle, while also accounting for those who arrive later from greater distances or move at lower speeds.
The developed model aims at reproducing the passenger service process typical of suburban bus operators, who most often use a single door for both boarding and alighting. The algorithm represents a sequential boarding–alighting model, in which the two processes occur consecutively. In the implemented algorithm, the model parameters were selected assuming uniform door utilization. For urban buses, the number of doors was explicitly considered when determining the unit boarding time () and unit alighting time (). The uneven distribution of door usage is represented by incorporating the standard deviation of the unit boarding and alighting times. The algorithm was structured to allow for further development in subsequent research, enabling its extension to more advanced representations of passenger service processes.
3.3.2. Parameters of the Simulation Model
The fundamental parameters of the simulation model were established based on the field data and multiple videos analyzes of passenger service processes at the surveyed bus stops. To calculate the total boarding and alighting time, it was necessary to estimate the unit boarding time and unit alighting time for individual passengers. These parameters were determined using data from the database of recorded events, selecting cases of intensive boarding and alighting, when queues of passengers formed when entering or exiting the bus.
The unit boarding time and unit alighting time for individual passengers were generated from a log-normal distribution with parameters estimated from the empirical dataset. This type of distribution was adopted based on previous studies and analyzes reported in the literature, e.g., [22], as well as on the results of the present investigation. Simulation experiments confirmed that the developed algorithm is not sensitive to the assumed distribution type; normal, gamma, and log-normal distributions were tested and yielded comparable results.
Using the complete dataset (without distinction by bus stop), the mean values (average time) and standard deviations of the boarding and alighting times were estimated according to Equations (6) and (8).
where
- —average unit boarding/alighting time per passenger (s/pass);
- —durations of intensive boarding/alighting for individual vehicles (s);
- —numbers of boarding/alighting passengers for consecutive vehicles (pass/veh);
- —number of analyzed vehicles;
- —expected sum of squared deviations from the average boarding/alighting time;
- —average boarding/alighting time per passenger for the i-th vehicle (s/pass).
Unit boarding and alighting times per passenger were sampled from a log-normal distribution adjusted to match the mean and standard deviation estimated for specific vehicle groups in which passenger boarding and alighting occurred. The estimated parameter values based on the field data are presented in Table 8. The results are divided into three operator categories. For the urban operator, an additional subdivision was made according to the number of doors.
Table 8.
Parameters of the unit boarding and alighting times estimated to calculate the total passenger service time in the simulation model.
The estimated parameters (Table 8) were higher than those reported for urban bus operations in previous studies [23]. However, the reference parameters were derived from a simulation model developed within a different algorithmic framework.
The average walking speed of passengers was estimated from video-based analyzes of the distance and travel time between the passenger’s waiting position on the platform and the bus entry point. To determine suitable values of passenger walking speed () for the model, simulation experiments were conducted. A normal distribution was assumed to represent random variations in walking speed. The simulations covered the following parameter ranges:
- Mean value: 1.4–2.4 m/s;
- Standard deviation: 0.1–0.6 m/s.
After each simulation run, the obtained results were compared with the field data. Based on the simulation analyzes, the average walking speed of passengers at the bus stop was set at 1.93 m/s, with a standard deviation of 0.3 m/s, corresponding to the simulation whose results showed the closest agreement with the empirical measurements.
3.3.3. Verification of the Simulation Model for Calculating Passenger Boarding and Alighting Time Using the Collected Field Data
Model performance was tested by performing at least 100 simulation runs of the passenger boarding and alighting process for each analyzed bus. The simulations were performed using the same number of boarding and alighting passengers as recorded in the measurement database and the same vehicle stopping positions at the bus stop. The averaged simulation results were compared with the field data and presented using linear regression plots shown in Figure 15 and Figure 16.
Figure 15.
Correlation between the measured passenger boarding and the alighting times and averaged simulated boarding and alighting times for urban bus operators vehicles.
Figure 16.
Correlation between the measured and averaged simulated passenger boarding and alighting times for vehicles of other users.
To evaluate the results of the simulations performed, standardized residuals (z-scores) were also calculated using the following formula:
where:
- —actual passenger boarding and alighting time for a given bus or other vehicle obtained from field measurements (s);
- —average passenger boarding and alighting time determined from 100 simulations for the same vehicle (s);
- —standard deviation of the boarding and alighting time obtained from 100 simulations for the same vehicle (s).
The calculated z-score values for the analyzed buses are presented as histograms in Figure 17, separately for vehicles of the urban operator and for other users’ vehicles.
Figure 17.
Histograms of z-score values for averaged simulation results and measured passenger boarding and alighting times: (a) for vehicles of urban bus operators, (b) for vehicles of other users.
Figure 18 presents the calculated z-score values for the entire collected dataset, along with the fitted probability density function of the normal distribution.
Figure 18.
Histogram of z-score values for averaged simulation results and measured passenger boarding and alighting times for all operator groups, with a fitted normal probability density function.
Figure 17 and Figure 18 illustrate the degree of agreement between the simulation results and the observed data. Based on the z-score analysis, approximately 95% of the obtained results fall within the range of −2 to 2, which indicates satisfactory performance according to standard evaluation criteria for this type of measure. For a simulation to accurately reflect real-world conditions, the distribution of standardized differences represented by the histograms should follow a normal distribution. This assumption was adopted based on the central limit theorem, which states that a random variable defined as the sum of independent random variables tends toward a normal distribution. Each simulation of passenger boarding and alighting time was performed independently, meaning that each result represents an independent random variable. It was concluded that the differences distribution of the analyzed is sufficiently consistent with the normal distribution to consider the simulations as accurately representing the passenger boarding and alighting process at the bus stops where field measurements were conducted. However, to verify whether the developed model can reliably reproduce boarding and alighting processes at other bus stops, additional field observations are required.
The developed boarding and alighting model provides a more detailed and realistic representation of the process compared to approaches that treat the total boarding and alighting time as a single random variable. It also allows integration with the vehicle stopping position model and the associated decision-making process related to initiating passenger boarding and alighting at specific points along the stop. The algorithm has an open structure, which enables further refinement of the developed model in future studies, including the incorporation of bus occupancy levels and the uneven distribution of passenger flow across the doors used for boarding and alighting.
4. Discussion
The results obtained confirm the validity of the research hypotheses formulated in Section 1.5 and indicate significant differences in the passenger service system at bus stops shared by multiple operators. In particular, the findings demonstrate that fleet heterogeneity, irregular vehicle stopping positions, and spatial dispersion of waiting passengers are key factors influencing the passenger boarding and alighting process, and, consequently, the overall dwell time of vehicles at bus stops. The analyses show that both passenger waiting positions and vehicle stopping positions exhibit strongly asymmetric probabilistic characteristics, consistent with earlier studies reporting asymmetric distributions of microscopic operational variables [15,25,26].
In the context of national studies, the results corroborate previous findings on the high variability of dwell times under disturbed operational conditions [20,33], while extending these observations to cases involving bus stops with unregulated passenger service patterns and shared-use boarding positions among various operators. Compared to international studies, e.g., [18,20,26,35], the analyses presented here offer an important contribution, as most existing models have focused on homogeneous systems with clearly defined passenger service rules and ordered vehicle movements. This study demonstrates that under real-world conditions characterized by heterogeneous fleets and shared-use stops, conventional dwell time and boarding/alighting models are insufficient. In contrast to standard approaches based on homogeneous and structured bus stop operations (FIFO/NO/LO/FO) commonly applied in the literature and in modeling practice, the present findings indicate that vehicle heterogeneity, platform sharing, and irregular stopping positions lead to significantly higher operational variability than predicted by traditional models [15,18,39,40]. The application of a microscopic approach to passenger-vehicle interaction and the estimation of probability distributions using customized data transformation methods enabled a more precise representation of user behavior and passenger–vehicle–environment interactions. These results align with the growing body of research emphasizing the need for probabilistic modeling of passenger boarding/alighting and total dwell time [15,35], while extending this framework to shared-use bus stops with multiple operators and complex interaction dynamics [43].
The statistical fitting of distributions to microscopic variables confirmed the strongly skewed nature of passenger waiting positions and passenger service times at shared-use bus stops. This finding aligns with a wider research trend focusing on asymmetric distributions of operational variables, where dwell time has been modeled using log-normal, inverse Gaussian, log-logistic (Fisk) and Johnson’s SU distributions [25]. Subsequent studies have expanded these probabilistic and process-based approaches to capture the dynamics of the passenger platform [27,34,35,40]. The analysis further indicates that passenger waiting position distributions can be reliably parameterized using basic statistical moment estimates, which simplifies their implementation in simulation models.
The developed simulation model also confirmed that individual passenger boarding and alighting times, as well as passenger walking speeds, exhibit systematic variability dependent on operator type (urban, suburban, and taxis/other vehicles) and vehicle characteristics. Consequently, passenger arrival times at vehicles depend on both spatial factors and probabilistic walking dynamics.
Given the substantial differences observed in passenger service efficiency between urban and suburban operators, taxis, and other vehicles, the analysis confirms the need to distinguish these groups in both modeling and operational studies of bus stop performance. Separate modeling of bay occupancy time for these groups is recommended, as differences arise from vehicle characteristics, passenger service procedures (e.g., on-board ticket purchases in intercity services), as well as operational patterns (choice of stopping position, variable number of active service bays). The results indicate that at bus stops serving intercity routes, an additional component of the bay occupation time should be considered, namely the passenger walking time to the bus, which depends on the spatial distribution of passenger waiting positions and vehicle stopping positions.
From a practical standpoint, the developed model provides a valuable tool for the design and the operational assessment of bus stops with complex, shared-use configurations. It can be applied to evaluate the efficiency of platform utilization, analyze the impact of additional bays on stop capacity, and support infrastructure management decisions regarding the admission of new operators while maintaining the required service quality and safety levels [15,18,40,43,63]. The model also allows uncertainty in dwell times to be explicitly represented (e.g., schedule buffers, vehicle allocation), aligning with the growing emphasis in the literature on accounting for variability rather than relying solely on average values [25,26,27,35].
At the present stage, quantitative system-level improvement metrics (e.g., vehicle delays, passenger delays, or queue lengths) cannot yet be consistently derived, as such indicators require full integration with a traffic flow model; this constitutes the next planned step of model development. The findings further suggest that modeling the spatial distribution and vehicle stopping positions should become a standard component of microscopic analyses of bus stop performance, particularly in congested urban environments. These operating conditions fundamentally limit the applicability of traditional bus stop modeling frameworks and highlight the need for more flexible, behavior-based approaches. As a result, capacity and reliability assessments based on simplified assumptions may be overly optimistic.
It should be emphasized that under free-choice stopping conditions, the desired stopping position is inherently highly stochastic in nature, as it is strongly driven by the dispersed spatial distribution of waiting passengers, particularly at stops used by suburban and intercity operators. This behavioral randomness fundamentally constrains the achievable explanatory power of purely deterministic models. At the same time, future research should aim to identify additional determinants that could partially reduce this unexplained variability. It should also be noted that these mechanisms are already embedded in a comprehensive bus stop simulation framework, in which real-time traffic conditions are dynamically represented using a car-following model and detailed stop geometry is explicitly incorporated [51].
The study also highlights the need for continued development of the model toward a comprehensive representation of processes occurring at shared-use bus stops. Future work should extend data collection to other cities with different geometric and operational characteristics to enable model calibration and validation across diverse spatial contexts. The present empirical validation is limited to two Polish cities; therefore, the assessment of model transferability to different traffic cultures and regulatory environments remains an important direction for future research. Further research should also address the effects of vehicle occupancy on passenger boarding and alighting dynamics and the uneven loading of doors used for boarding and alighting, as well as differences in service practices among operators. An important direction for development involves integrating the proposed model into a holistic microsimulation framework of bus stop operations that simultaneously captures passenger boarding and alighting processes and their influence on surrounding traffic flow.
In summary, the presented analyses provide a novel perspective on modeling dwell time and passenger boarding and alighting processes at shared-use bus stops. The proposed model, through its microscopic structure and probabilistic foundation, offers an effective approach for the design, planning, and management of public transport infrastructure in complex, multi-operator urban environments with high levels of operational variability.
5. Conclusions
Based on the analysis of passenger boarding and alighting efficiency at shared-use bus stops, the following conclusions were drawn. All conclusions below are directly supported by the empirical observations, statistical tests, and the developed simulation framework presented in this study, and they should be interpreted within the scope of the analyzed dataset.
- The position of vehicle stopping points at bus stops, defined relative to the centroid of waiting passengers, differs significantly between vehicles operated by urban transit agencies and those belonging to other users (long-distance operators, private cars, taxis, and other vehicles). No statistically significant differences were found between the stopping positions of intercity operators and other users (taxis and private vehicles). Therefore, in simulation models of bus stop operations, it is sufficient to distinguish two user groups: urban operators and other users.
- Statistical tests confirmed that the main factors influencing the stopping position of vehicles for passenger boarding and alighting are the type of user, the traffic situation (i.e., the type of vehicles arriving shortly after the analyzed vehicle), the presence or absence of boarding passengers, and the number of vehicles following the analyzed one.
- The low coefficients of determination (R2) and relatively high standard errors indicate that the developed multiple regression models explain only a small part of the variance in the dependent variable—vehicle stopping position during passenger boarding and alighting. This confirms that a substantial share of the stopping-position variability is not captured by deterministic predictors and is driven by stochastic effects observed in the data. Statistical analyses indicated that the spatial distribution of passenger waiting positions at bus stops was best represented by the beta distribution. For 17 of all analyzed stops serving urban operators, the beta distribution ranked among the two best-fitting models, while for other users it ranked within the top two fits in 8 out of 10 analyzed stops.
- The estimated parameters of the waiting positions before approaching the bus significantly vary depending on the location of the bus shelter, the passenger load at the stop (number of boarding passengers per hour), the type of bus stop (in-lane or in-bay), and the operator category. Heavily loaded stops exhibit higher standard deviations of passenger waiting positions.
- For urban operators, the centroid of the waiting passenger group can generally be approximated by the location of the bus shelter. For other users, a similar relationship holds at low-demand stops, where the average number of boarding passengers ≤ 100 pass/h. At more heavily loaded stops ( > 100 pass/h), the passenger’s centroid of the waiting for other users is located approximately 5–20 m farther along the platform than that of urban operators, depending on the average number of passengers boarding.
- The stopping positions of vehicles and the spatial dispersion of passenger waiting positions significantly influence both the passenger service process and traffic performance in the vicinity of the stop. These aspects should be explicitly considered in the design and operational assessment of public transport infrastructure. From an engineering perspective, they affect the geometric design parameters and traffic organization within and around the stop area.
- The developed detailed boarding and alighting model provides a more realistic representation of the process than approaches treating total passenger boarding and alighting time as a single random variable or modeling it solely through regression without considering the prevailing traffic situation. This modeling framework allows integration with other components of the bus stop operation model, including the vehicle stopping position model. The algorithm has an open architecture, enabling further refinement in future studies—particularly the inclusion of bus occupancy effects and the uneven use of doors during passenger boarding and alighting. Future work may also test the robustness of the proposed distributions and model parameters on additional stops and operating conditions.
Funding
This research was funded by the Kielce University of Technology, Poland, under Grant No. 02.0.09.00/1.02.001.SUBB.BKIK.25.001.
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
The raw data supporting the conclusions of this article will be made available by the authors on request.
Conflicts of Interest
The author declare no conflicts of interest.
Abbreviations
The following abbreviations are used in this manuscript:
| APC | Automatic Passenger Counter |
| AVL | Automatic Vehicle Location |
| FIFO | First In, First Out |
| NO | Nearside Overtaking |
| LO | Lead Overtaking |
| FO | Far-side Overtaking |
| MLE | Maximum Likelihood Estimation |
| MGF(AD) | Modified Goodness-of-Fit (Anderson–Darling) Statistic |
Appendix A. Parameters Describing Passenger Waiting Positions at Bus Stops
This appendix provides supplementary data for the analysis presented in Section 3.1.1. Table A1 summarizes the parameters of passenger waiting positions estimated from field measurements for the analyzed bus stops. The locations of bus shelters were determined relative to the adopted 0 m reference cross section. In cases where two shelters were separated by a kiosk, their total length was taken into account.
Table A1.
Summary of passenger waiting position parameters estimated from field measurement samples for analyzed bus stops (SD—standard deviation, —average hourly number of boarding passengers).
Appendix B. Results of Hypothesis Verification Concerning the Stopping Position of Vehicles at Bus Stops
This appendix presents the results of hypothesis verification described in Section 3.2.1. The results of the Tukey HSD multiple comparison tests for the variable are summarized in Table A2. For each pair of variables, the mean difference (Δ), its standard error (±), and the probability (p-value) of the post hoc tests are provided.
The results of the variance analysis for the variable under the analyzed traffic situations, obtained as part of the verification of research hypotheses 2 and 3, are summarized in Table A3.
Table A2.
Results of multiple comparison tests of Tukey HSD for the variable by user groups (verification of hypothesis 1).
Table A3.
Descriptive statistics and results of the variance analysis for the variable under the traffic situations (hypotheses 2 and 3).
The results of the Tukey HSD multiple comparison tests for the variable , depending on the traffic situation, are summarized in Table A4. For each pair of variables, the mean difference Δ and its standard error (given after the ± sign) as well as the probability (p-value) for the post hoc tests are provided.
Table A4.
Results of multiple comparisons (Tukey HSD method) of variable values by group (hypotheses 2 and 3).
Appendix C. Detailed Description of the Passenger Boarding and Alighting Time Algorithm
This appendix presents the internal structure of the microsimulation model of the passenger boarding and alighting process described in Section 3.3.
The simulation procedure that represents passenger service at the bus stop consists of three main blocks (Figure A1, Figure A2 and Figure A3). The core algorithm that describes the passenger boarding and alighting process is included in Block B 1.2 (calculation of passenger alighting time) and Block B 1.3 (calculation of passenger boarding time). Block B 1.1 (data input) together with Block B 1.1a (initialization of the boarding passenger queue) forms a complementary part of the procedure.
The execution of the boarding and alighting simulation stages enables the determination of the total passenger boarding and alighting time. The start of the boarding and alighting process, in cases where no passengers are alighting or only a few passengers are leaving the vehicle, occurs at the moment when the first passenger reaches the bus. For buses equipped with automatically operated doors, it was assumed, based on field measurements, that the boarding and alighting process cannot begin earlier than two seconds after the vehicle stops at the bus stop, even if the access time of the first passenger is shorter.
The input to the algorithm includes the following data required to calculate the total passenger boarding and alighting time:
- A value drawn from the corresponding probability distribution representing the stopping position at the bus stop (POSITION, Pz);
- A set of individual alighting times for successive passengers drawn from the respective probability distribution (TIME_ALG, ta);
- A set of individual boarding times for successive passengers drawn from the respective probability distribution (TIME_BRD, tb);
- A set of passengers waiting positions on the bus stop platform for boarding passengers drawn from the relevant probability distribution (POSITION, xp);
- A set of walking speeds of boarding passengers drawn from the appropriate probability distribution (SPEEDS, Vpas).
Logical expressions can take only two values, represented as 0 or 1, while in the presented algorithms they are denoted as TRUE or FALSE.
The simulation is performed through successive realizations of discrete events. Each subsequent event is processed (activated) by the iterator TIMES_IT, which provides access to the event. For every iteration, the next chronologically following event from the dictionary TIMES is selected.
Figure A1.
Diagram of the data input block (B 1.1) and the algorithm for calculating passenger alighting time (block B 1.2).
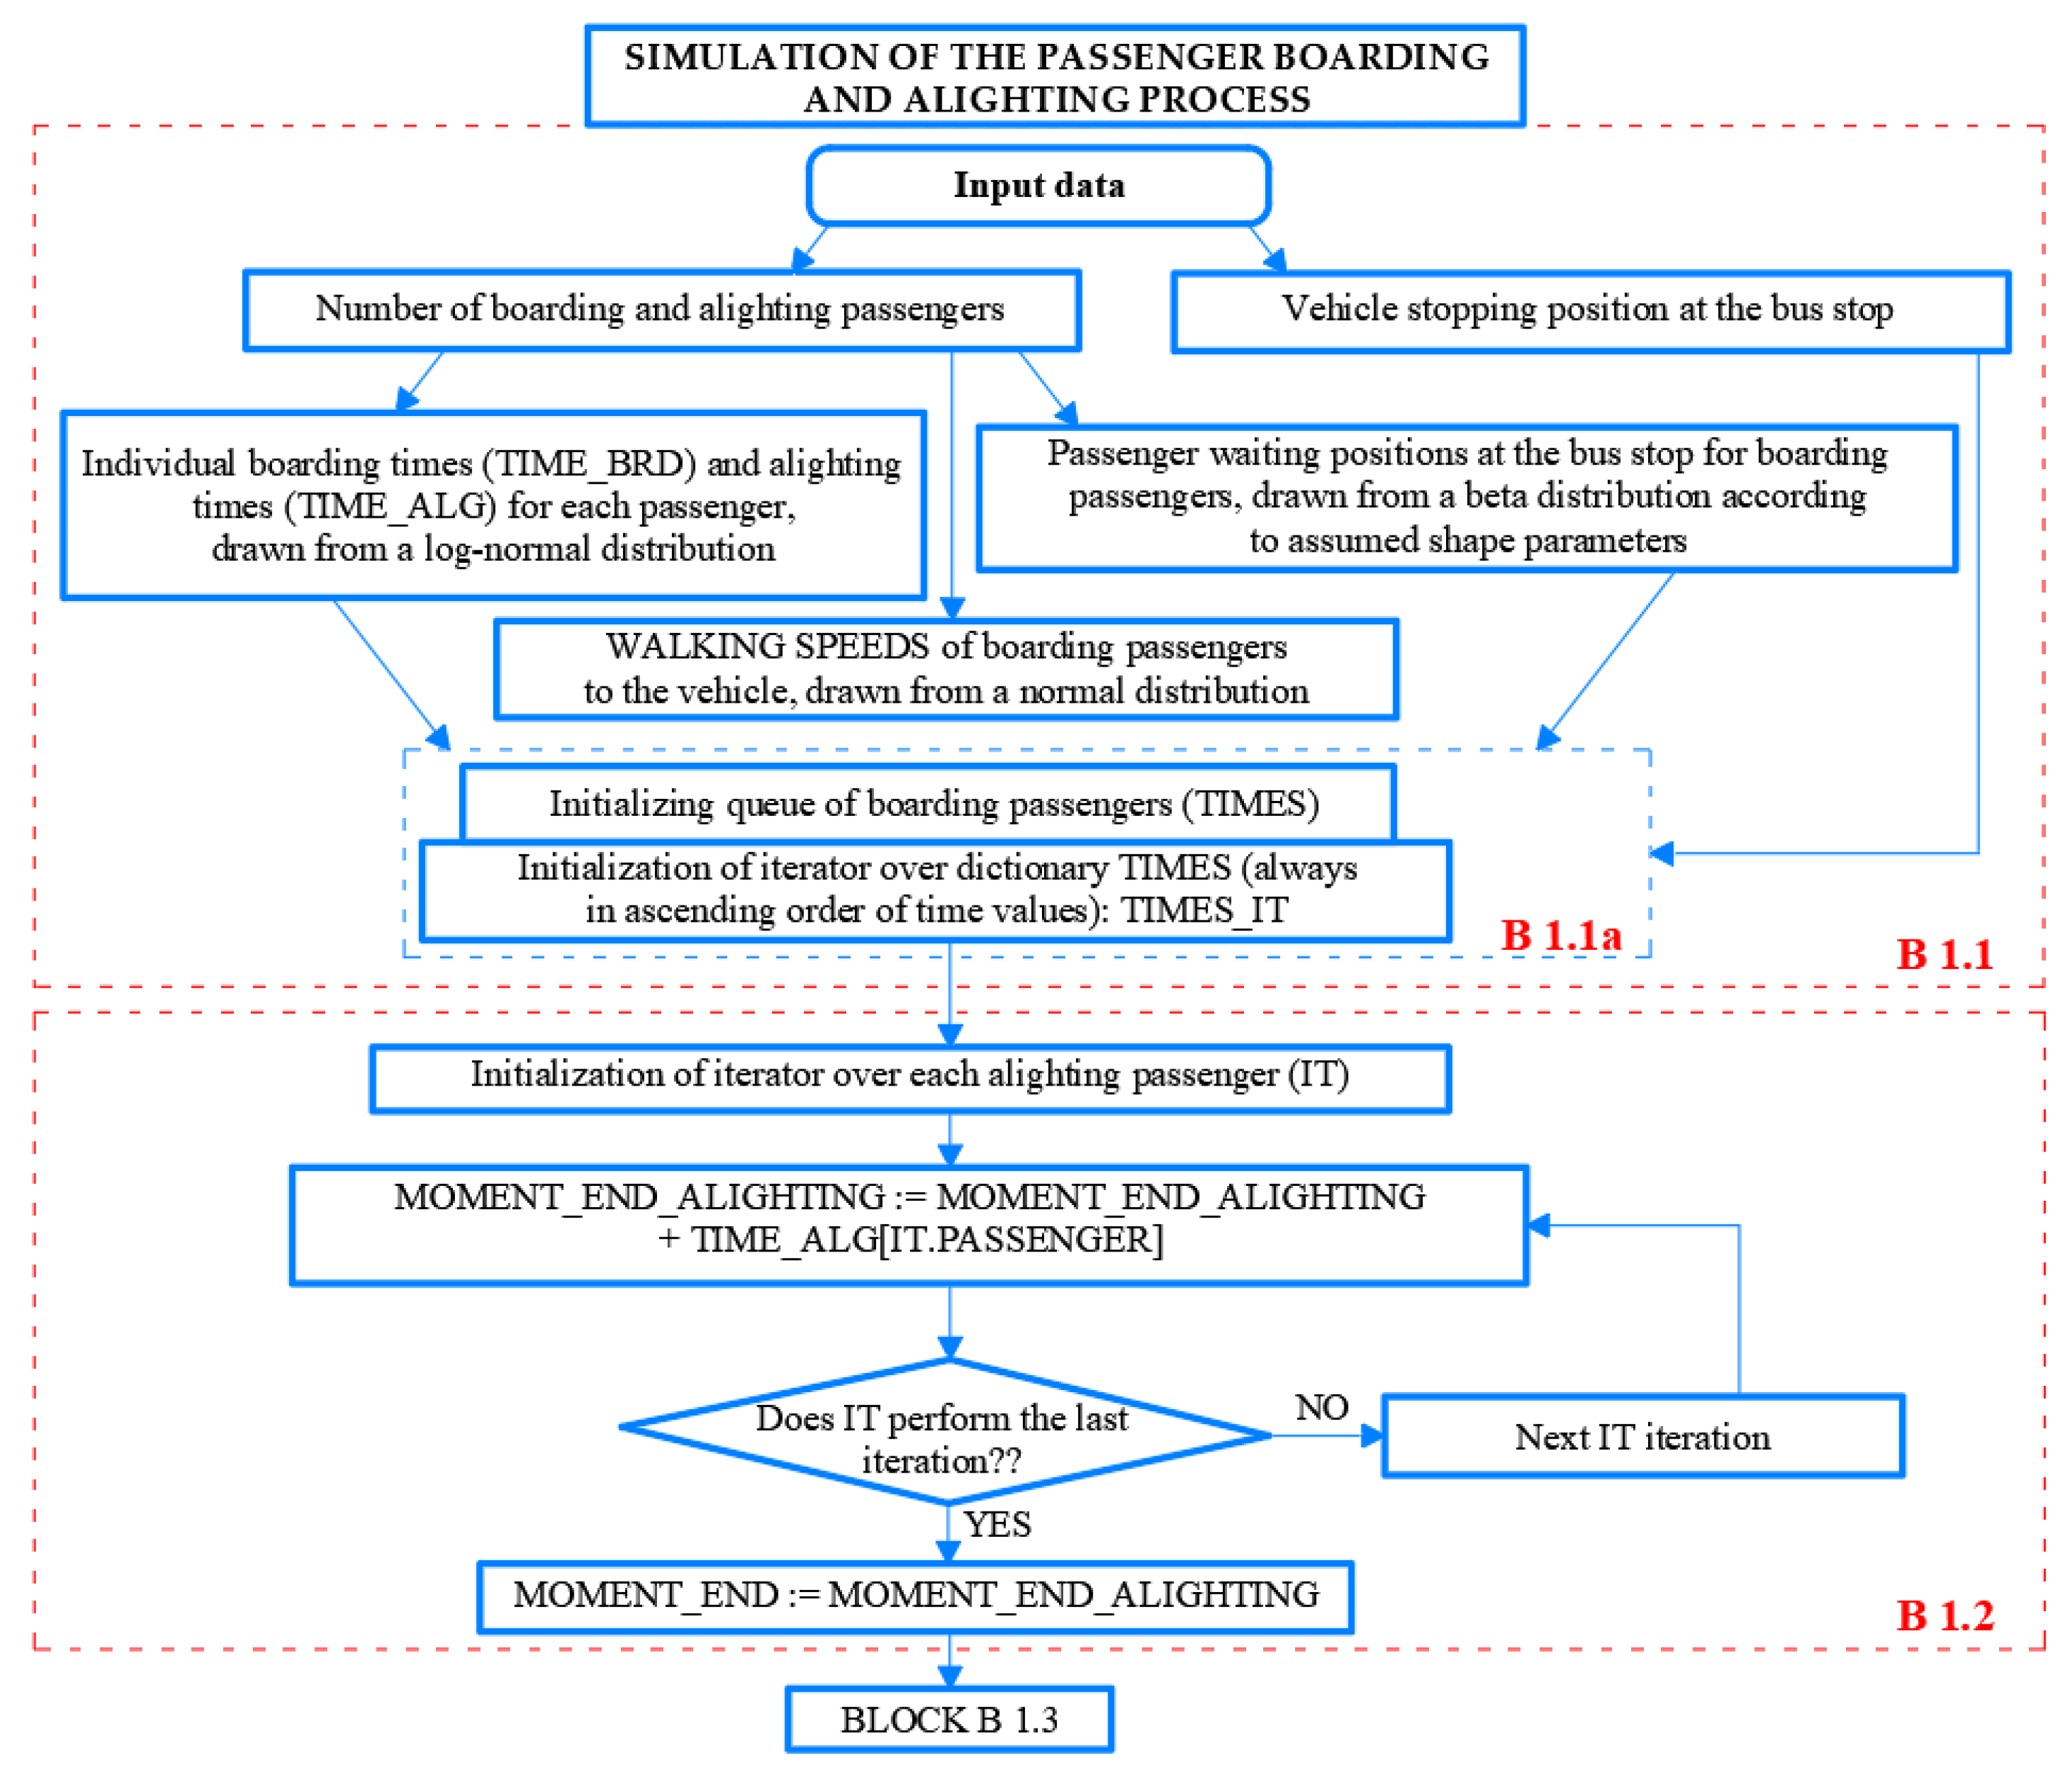
The algorithm uses an iterator applied to an ordered dictionary of events. This dictionary represents the currently analyzed queue of future events (the current program step that processes that queue) and has the following structure: event time (key) event ID (boolean value).
Figure A2.
Flow chart of the algorithm to initialize the queue of passengers boarding (block B 1.1a).
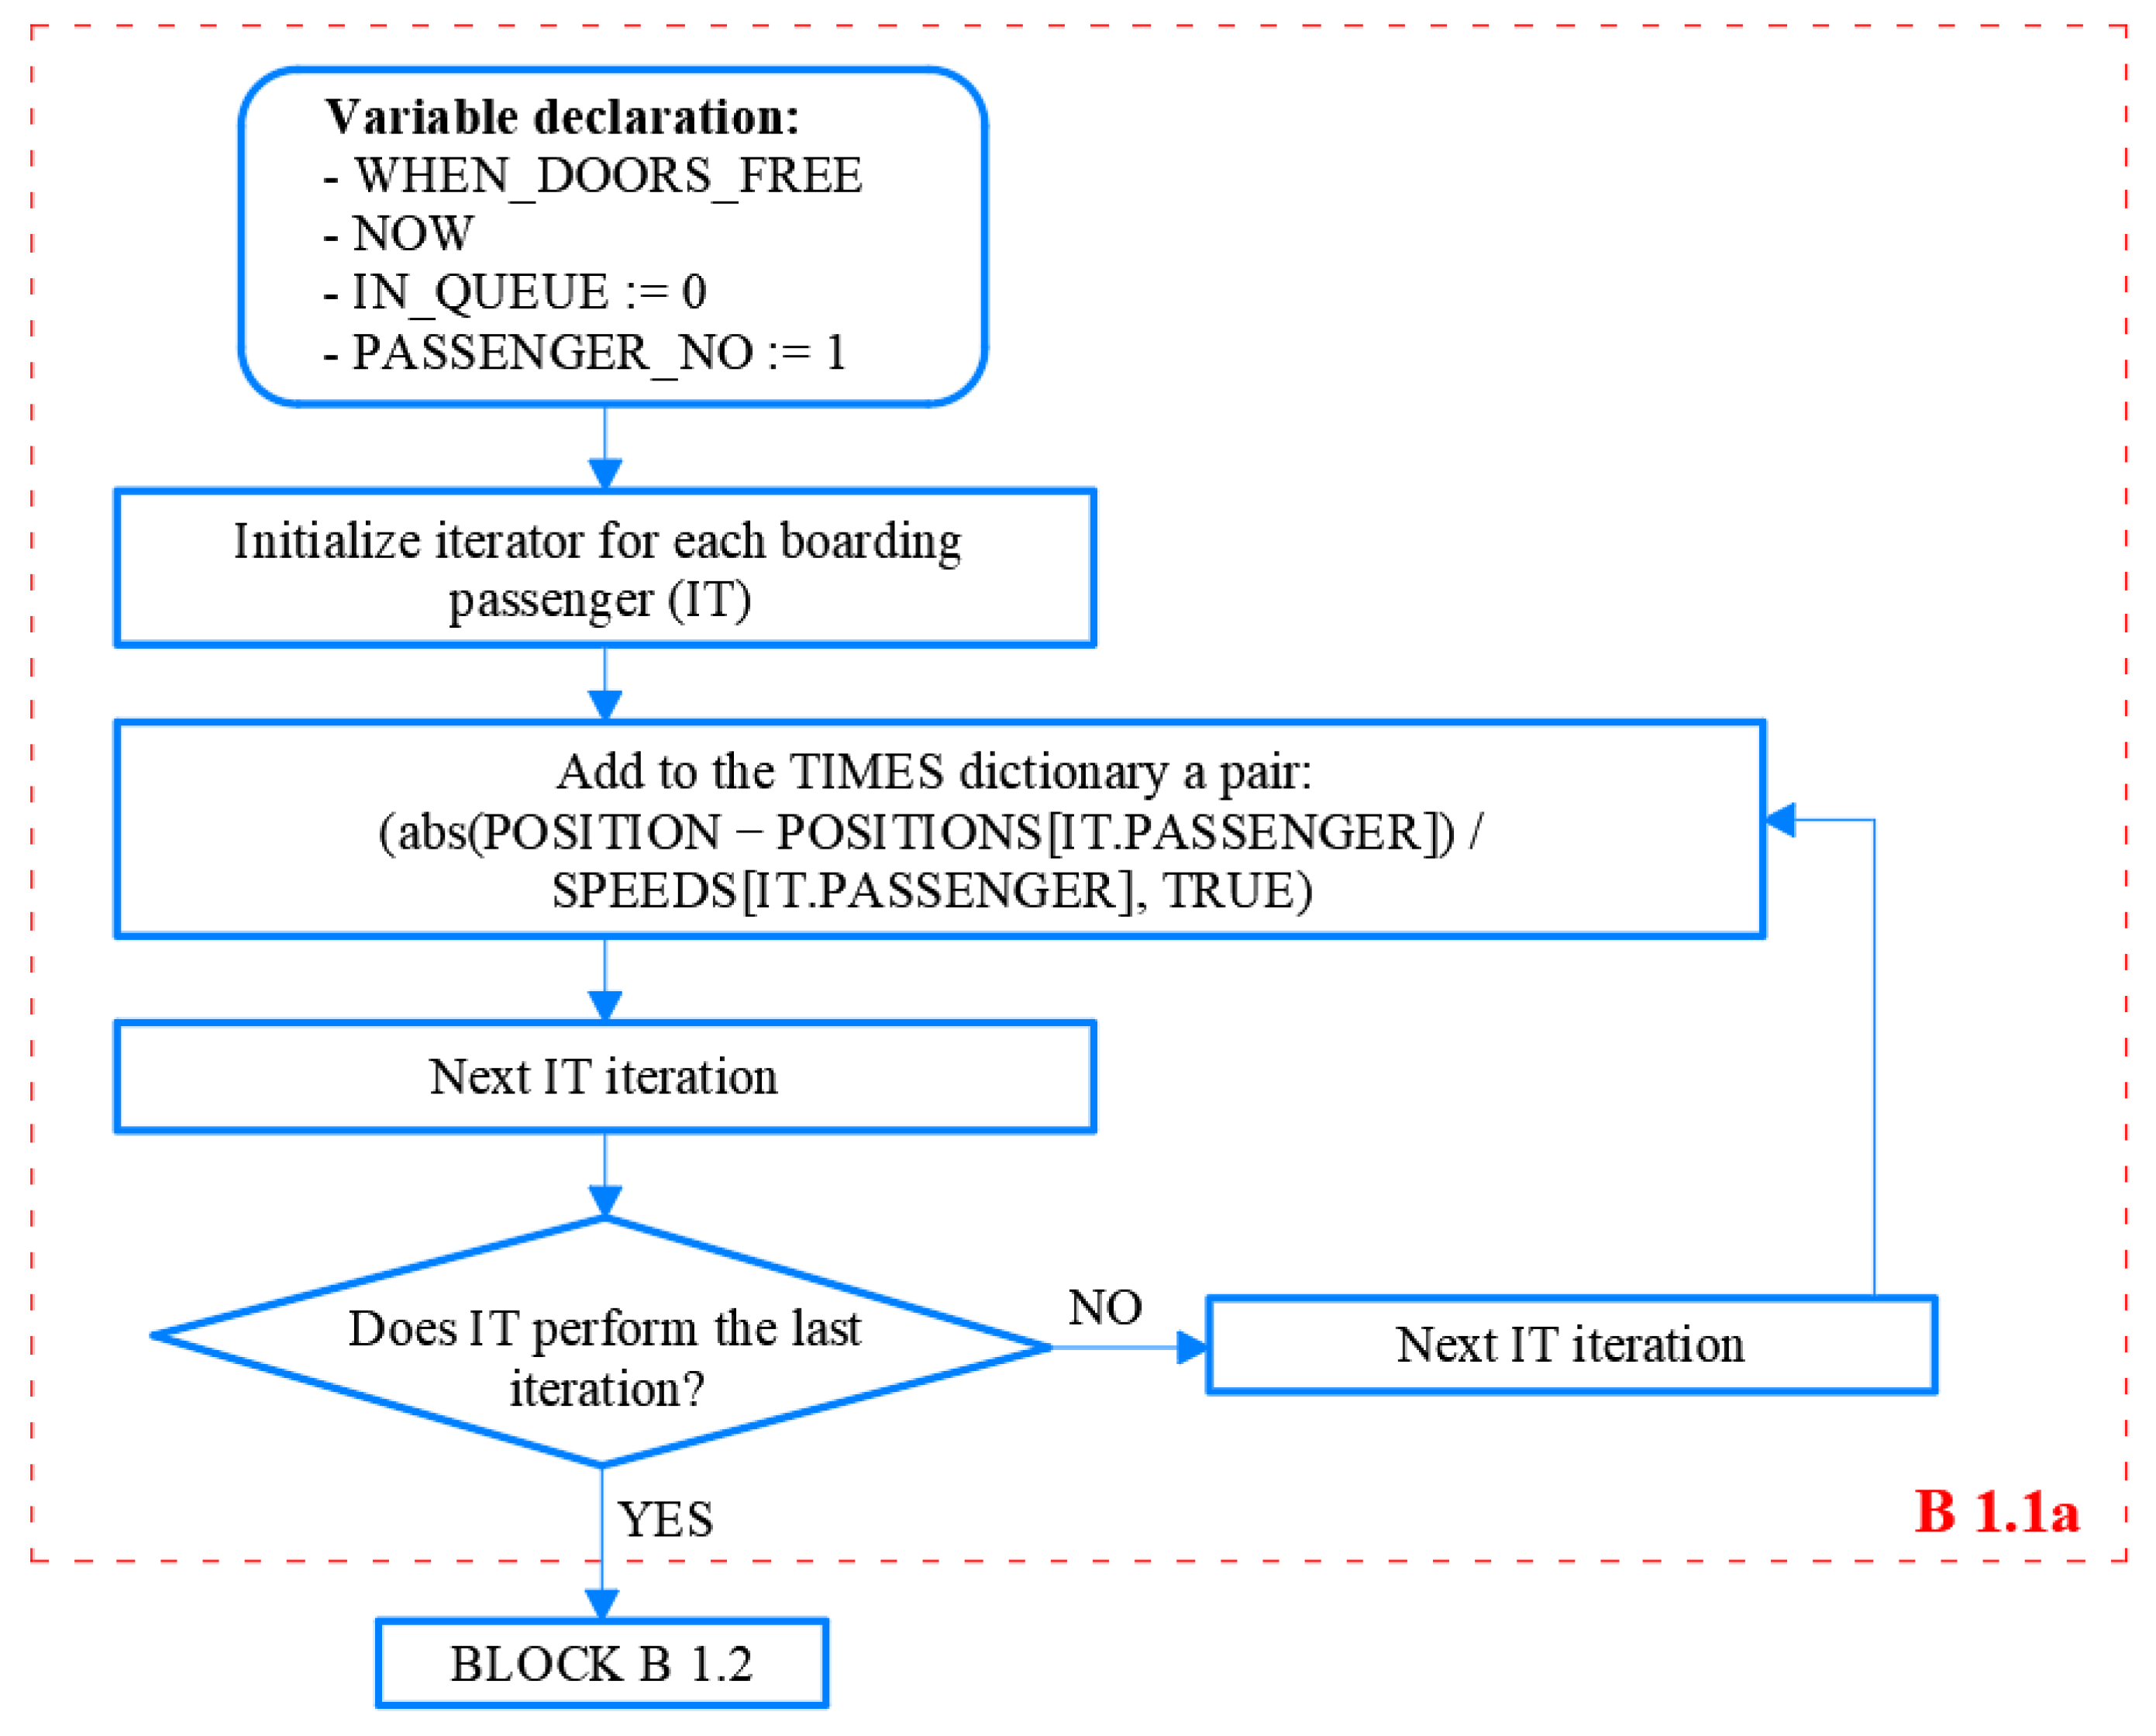
Two types of events are defined in the simulation procedure:
- “Passenger boarded the vehicle” (event_ID = TRUE);
- “Passenger joined the queue of boarding passengers” (event_ID = FALSE).
The instance of this dictionary is referred to as TIMES, and its iterator (always iterating in ascending order of time values) is referred to as TIMES_IT. After each i-th boarding passenger, an iteration is executed. Events with the TRUE value and a key equal to the expression absolute value (POSITION POSITIONS [i])/SPEEDS[i] are added to the boarding queue.
The following variable declarations are used in the algorithm:
- WHEN_DOORS_FREE—the earliest moment when the next passenger may begin boarding;
- NOW—the current simulation time;
- IN_QUEUE—an integer variable indicating the current number of passengers waiting in the boarding queue; it is used to determine whether there are still passengers waiting;
- PASSENGER_NO—an integer variable identifying the passenger number used to retrieve the corresponding TIME_BRD.
The output of the algorithm is the total passenger boarding and alighting time (a single scalar value).
Figure A3.
Flow chart of the algorithm to calculate the passenger boarding time (block B 1.3).
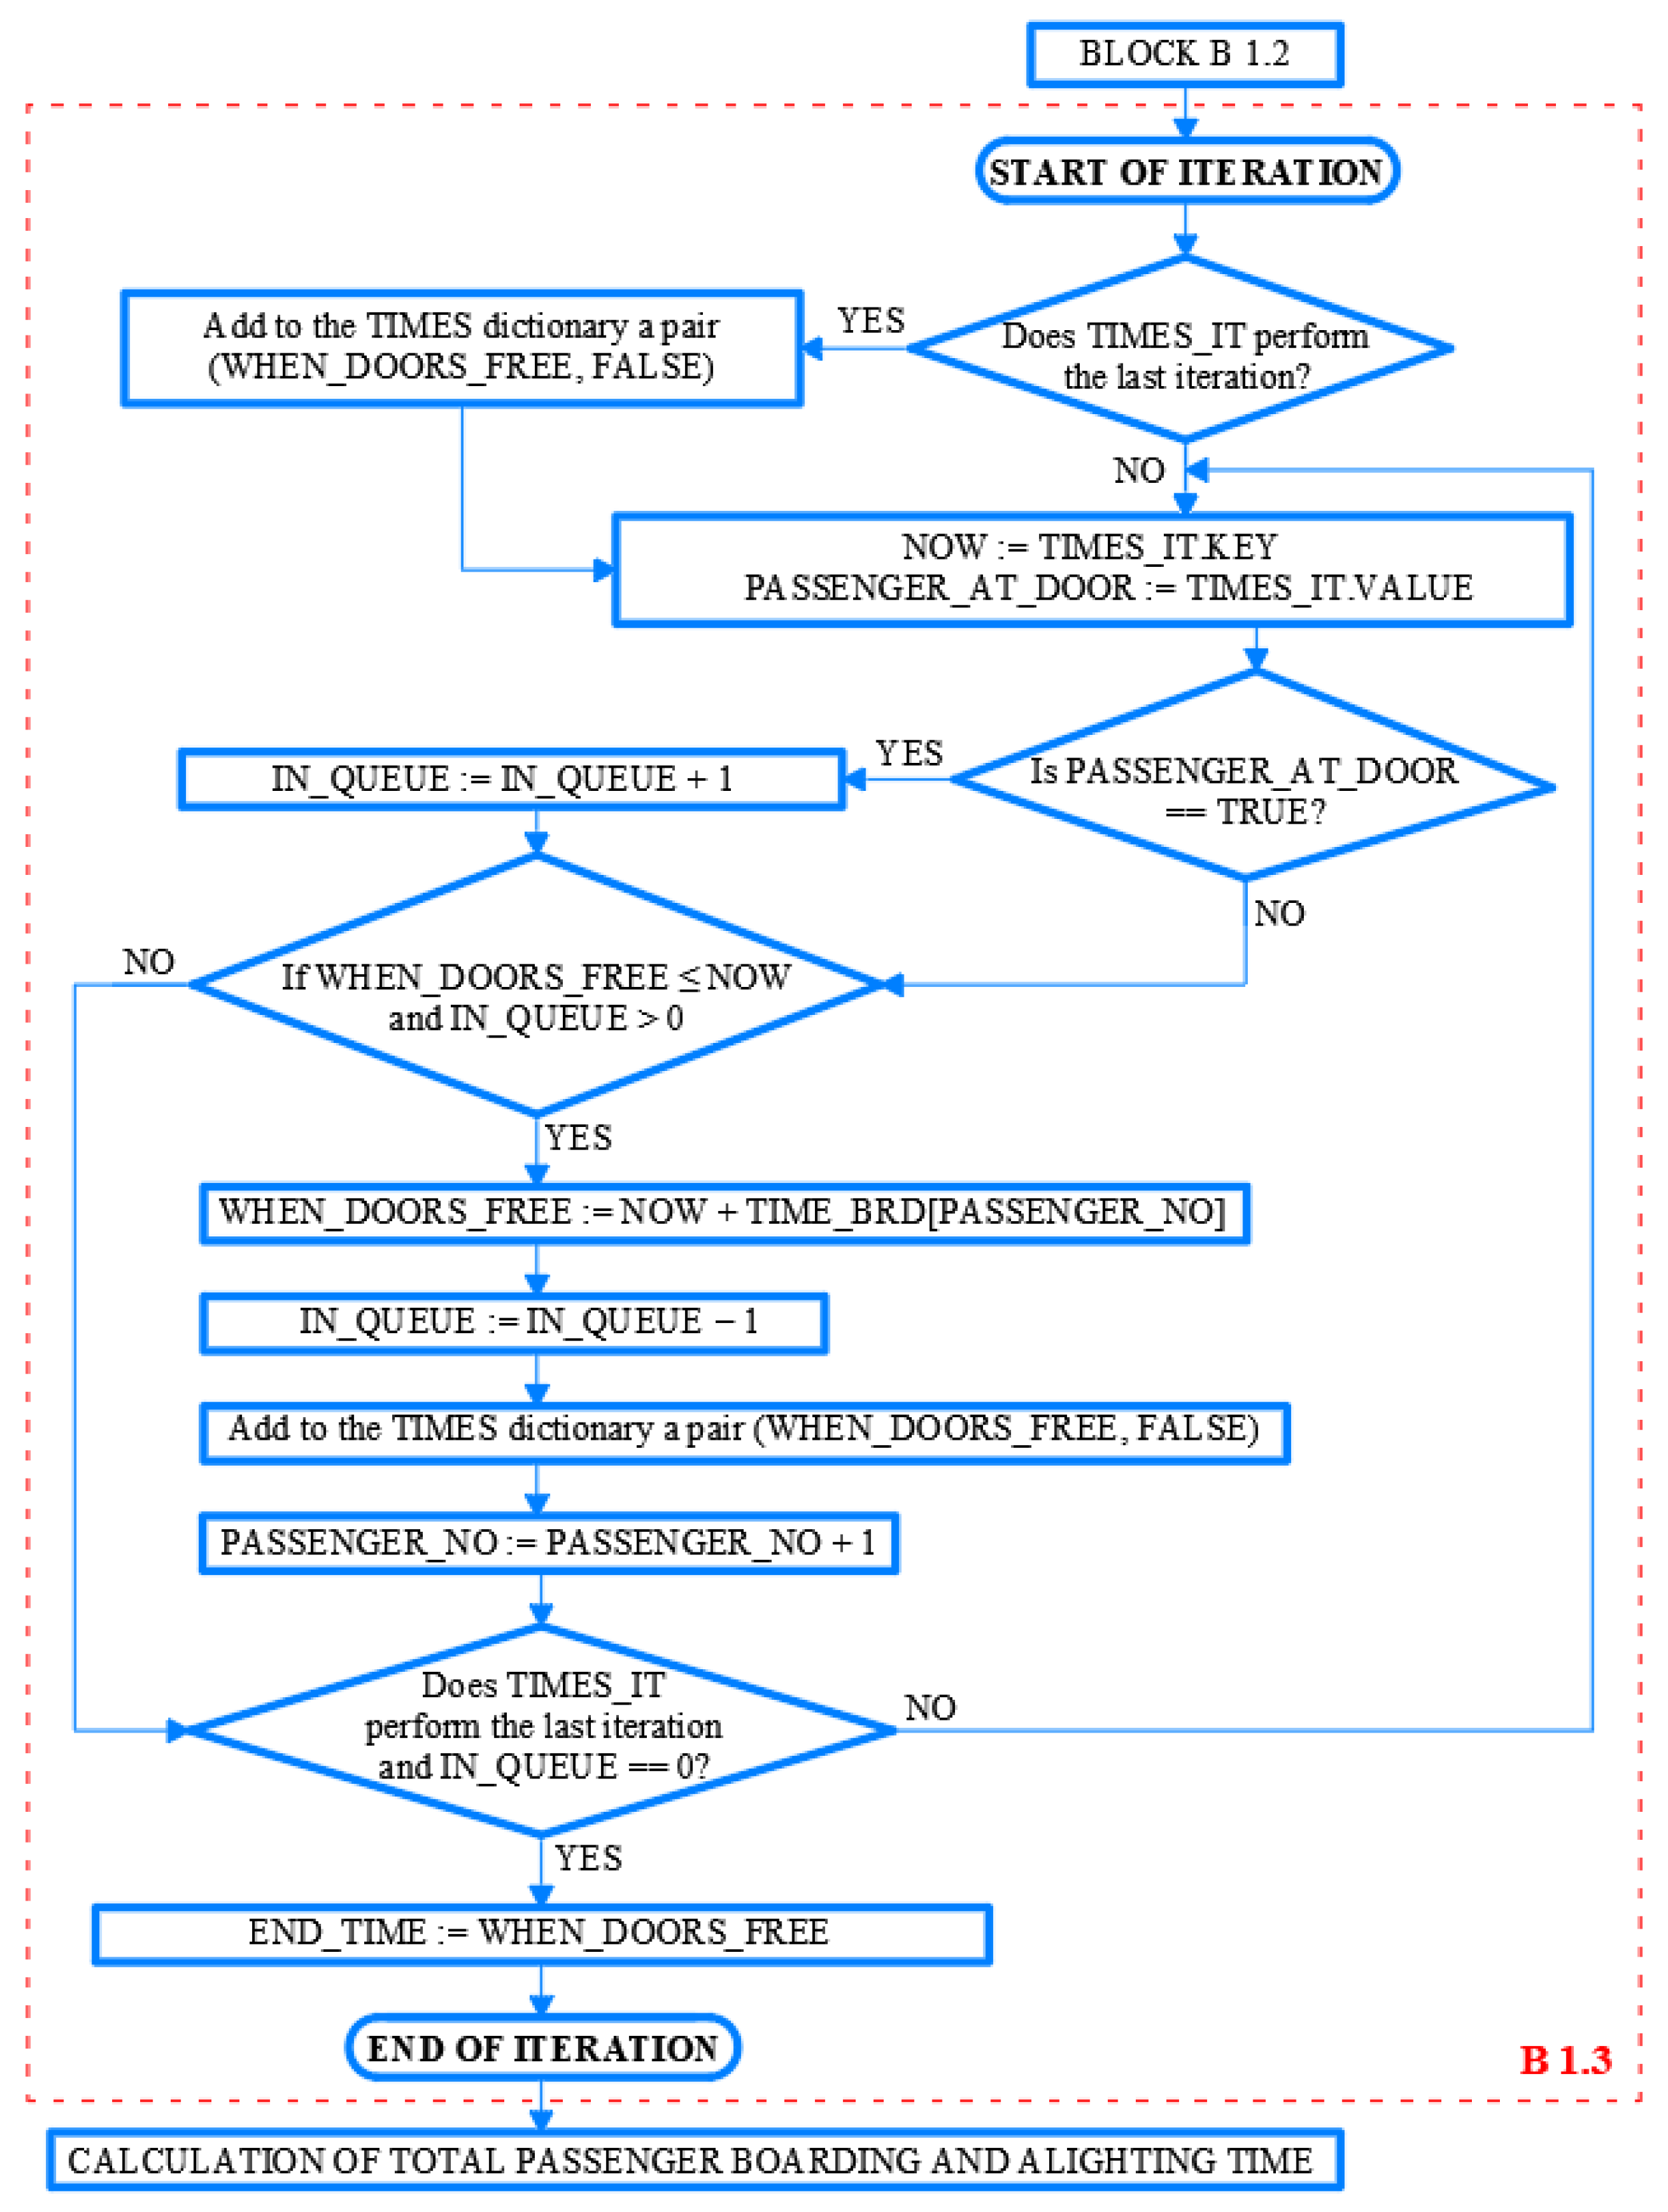
References
- Nanaki, E.A.; Koroneos, C.J.; Roset, J.; Susca, T.; Christensen, T.H.; De Gregorio Hurtado, S.; Rybka, A.; Kopitovic, J.; Heidrich, O.; López-Jiménez, P.A. Environmental Assessment of 9 European Public Bus Transportation Systems. Sustain. Cities Soc. 2017, 28, 42–52. [Google Scholar] [CrossRef] [Scilit]
- Jing, Q.-L.; Liu, H.-Z.; Yu, W.-Q.; He, X. The Impact of Public Transportation on Carbon Emissions—From the Perspective of Energy Consumption. Sustainability 2022, 14, 6248. [Google Scholar] [CrossRef] [Scilit]
- Minelgaitė, A.; Dagiliūtė, R.; Liobikienė, G. The Usage of Public Transport and Impact of Satisfaction in the European Union. Sustainability 2020, 12, 9154. [Google Scholar] [CrossRef] [Scilit]
- Göransson, J.; Andersson, H. Factors That Make Public Transport Systems Attractive: A Review of Travel Preferences and Travel Mode Choices. Eur. Transp. Res. Rev. 2023, 15, 32. [Google Scholar] [CrossRef] [Scilit]
- The New EU Urban Mobility Framework. Available online: https://eur-lex.europa.eu/legal-content/EN/TXT/?uri=CELEX:52021DC0811 (accessed on 27 October 2025).
- Sustainable and Smart Mobility Strategy—Putting European Transport on Track for the Future. Available online: https://eur-lex.europa.eu/legal-content/EN/TXT/?uri=CELEX:52020DC0789 (accessed on 27 October 2025).
- Guidelines for Developing and Implementing a Sustainable Urban Mobility Plan (2nd Edition). Available online: https://www.researchgate.net/publication/374913351_Guidelines_for_developing_and_implementing_a_Sustainable_Urban_Mobility_Plan_2nd_edition (accessed on 27 October 2025).
- International Transport Forum. The Future of Passenger Mobility and Goods Transport in Estonia; International Transport Forum Policy Papers; OECD/ITF: Paris, France, 2020; Volume 78. [Google Scholar]
- Pojani, D.; Stead, D. Sustainable Urban Transport in the Developing World: Beyond Megacities. Sustainability 2015, 7, 7784–7805. [Google Scholar] [CrossRef] [Scilit]
- Taylor, Z.; Ciechański, A. Systemic Transformation and Changes in Surface Transport Companies in Poland: A Synthesis After Twenty-Five Years. J. Transp. Geogr. 2018, 70, 114–122. [Google Scholar] [CrossRef] [Scilit]
- Fitzová, H.; Matulová, M. Comparison of Urban Public Transport Systems in the Czech Republic and Slovakia: Factors Underpinning Efficiency. Res. Transp. Econ. 2020, 81, 100824. [Google Scholar] [CrossRef] [Scilit]
- Oszter, V. Transport Policies in Hungary—Historical Background and Current Practice for National and Regional Level. Eur. Transp. Res. Rev. 2017, 9, 20. [Google Scholar] [CrossRef] [Scilit]
- Hansson, J.; Pettersson, F.; Svensson, H.; Wretstrand, A. Preferences in Regional Public Transport: A Literature Review. Eur. Transp. Res. Rev. 2019, 11, 38. [Google Scholar] [CrossRef] [Scilit]
- Transportation Research Board. Transit Capacity and Quality of Service Manual, 4th ed.; The National Academies of Sciences, Engineering, and Medicine: Washington, DC, USA, 2023. [Google Scholar]
- Bąk, R. Simulation Model of the Bus Stop. Arch. Transp. 2010, 1, 5–25. [Google Scholar] [CrossRef] [Scilit]
- Fernandez, R.; Tyler, N. Effect of Passenger–Bus–Traffic Interactions on Bus Stop Operations. Transp. Plan. Technol. 2005, 28, 273–292. [Google Scholar] [CrossRef] [Scilit]
- Li, R.; Yang, Q.; Qi, T.; Xue, X. Simulation Analysis of Capacity Evaluation of Bus Stops under Connected and Automated Vehicles Environment. Appl. Sci. 2023, 13, 9186. [Google Scholar] [CrossRef] [Scilit]
- Fernández, R. Modelling Public Transport Stops by Microscopic Simulation. Transp. Res. Part C Emerg. Technol. 2010, 18, 856–868. [Google Scholar] [CrossRef] [Scilit]
- Shi, H.; Luo, L.; Bao, T. Research on the Way to Determine Types and Scales of Bus Stops. J. Transp. Syst. Eng. Inf. Technol. 2007, 7, 83–86. [Google Scholar] [CrossRef] [Scilit]
- Tirachini, A.; Hensher, D.A.; Rose, J.M. Multimodal Pricing and Optimal Design of Urban Public Transport: The Interplay between Traffic Congestion and Bus Crowding. Transp. Res. Part B Methodol. 2014, 61, 33–54. [Google Scholar] [CrossRef] [Scilit]
- Molecki, A.; Sobota, A. Zależność Czasu Wymiany Pasażerów Autobusu Od Liczby Pasażerów Korzystających z Przystanku [Relationship between Bus Passenger Boarding and Alighting Time and the Number of Passengers Served at the Stop]. Autobusy 2008, 5, 20–28. (In Polish) [Google Scholar]
- Molecki, A. Wykorzystanie Rozkładu Logarytmiczno-Normalnego Do Modelowania Czasu Wymiany Pasażerów [Modeling Passenger Boarding and Alighting Time Using the Lognormal Distribution]. In Zeszyty Naukowe Politechniki Śląskiej; Seria: Transport, Zeszyt 65; Politechnika Śląska: Katowice, Poland, 2009. (In Polish) [Google Scholar]
- Bauer, M. Modelowanie Czasu Wymiany Pasażerów [Modeling of Passenger Boarding and Alighting Time]. Transp. Miej. i Reg. 2008, 4, 24–30. (In Polish) [Google Scholar]
- Fletcher, G.; El-Geneidy, A. Effects of Fare Payment Types and Crowding on Dwell Time. Transp. Res. Rec. J. Transp. Res. Board 2013, 2351, 124–132. [Google Scholar] [CrossRef] [Scilit]
- Rashidi, S.; Ataeian, S.; Ranjitkar, P. Estimating Bus Dwell Time: A Review of the Literature. Transp. Rev. 2022, 43, 32–61. [Google Scholar] [CrossRef] [Scilit]
- Kwesiga, D.K.; Guin, A.; Hunter, M. Analysis of Bus Dwell Times from Automated Passenger Count Data and the Impact of Dwell-Time Variability on the Performance of Transit Signal Priority. Public Transp. 2025. [Google Scholar] [CrossRef] [Scilit]
- Wang, T.; Huang, L.; Tian, J.; Zhang, J.; Yuan, Z.; Zheng, J. Bus Dwell Time Estimation and Overtaking Maneuvers Analysis: A Stochastic Process Approach. Transp. Res. Part E Logist. Transp. Rev. 2024, 186, 103577. [Google Scholar] [CrossRef] [Scilit]
- Zhou, X.; Guo, H.; Li, B.; Zhao, X. Transit Dynamic Operation Optimization Using Combination of Stop-Skipping Strategy and Local Route Optimization. Appl. Sci. 2024, 14, 7783. [Google Scholar] [CrossRef] [Scilit]
- Lu, Y.; Du, C.; Shao, Y.; Zhou, J. Characterization of Rapeseed Oil Using FTIR-ATR Spectroscopy. J. Food Sci. Eng. 2014, 4, 244–249. [Google Scholar]
- Guo, C.; Wang, J.; Jian, M.; Liu, Z.; Huo, Y. A Model of a Limited-Stop and Local Mixed Bus Service with Increased Fares for the Limited-Stop Service. Appl. Sci. 2022, 12, 11411. [Google Scholar] [CrossRef] [Scilit]
- Li, M.-T.; Zhao, F.; Chow, L.-F.; Zhang, H.; Li, S.-C. Simulation Model for Estimating Bus Dwell Time by Simultaneously Considering Numbers of Disembarking and Boarding Passengers. Transp. Res. Rec. J. Transp. Res. Board 2006, 1971, 59–65. [Google Scholar] [CrossRef]
- Bie, Y.; Wang, Y.; Zhang, L. Impact of Carriage Crowding Level on Bus Dwell Time: Modelling and Analysis. J. Adv. Transp. 2020, 2020, 6530530. [Google Scholar] [CrossRef] [Scilit]
- Novales, M.; Orro, A.; Pérez-López, J.-B.; Feal, J.; Bugarín, M. Increasing Boarding Lost Time at Regular Bus Stops during Rainy Conditions: A Case Study. J. Public Transp. 2021, 23, 63–80. [Google Scholar] [CrossRef] [Scilit]
- Adamski, A. Probabilistic Models of Passengers Service Processes at Bus Stops. Transp. Res. Part B Methodol. 1992, 26, 253–259. [Google Scholar] [CrossRef] [Scilit]
- Meng, Q.; Qu, X. Bus Dwell Time Estimation at Bus Bays: A Probabilistic Approach. Transp. Res. Part C Emerg. Technol. 2013, 36, 61–71. [Google Scholar] [CrossRef] [Scilit]
- Yan, M.; Xie, B.; Xu, G. Identifying Spatial–Temporal Characteristics and Significant Factors of Bus Bunching Based on an EGA and DT Model. Appl. Sci. 2022, 12, 11778. [Google Scholar] [CrossRef] [Scilit]
- Isukapati, I.K.; Igoe, C.; Bronstein, E.; Parimi, V.; Smith, S.F. Hierarchical Bayesian Framework for Bus Dwell Time Prediction. IEEE Trans. Intell. Transp. Syst. 2021, 22, 3068–3077. [Google Scholar] [CrossRef] [Scilit]
- Sun, W.; Schmöcker, J.-D.; Fukuda, K. Estimating the Route-Level Passenger Demand Profile from Bus Dwell Times. Transp. Res. Part C Emerg. Technol. 2021, 130, 103273. [Google Scholar] [CrossRef] [Scilit]
- Rudnicki, A. Symulacja Funkcjonowania Przystanku Autobusowego [Simulation of the Functioning of a Bus Stop]. Arch. Inżynierii Lądowej 1977, 1. (In Polish) [Google Scholar]
- Hu, S.; Shen, M.; Gu, W. Impacts of Bus Overtaking Policies on the Capacity of Bus Stops. Transp. Res. Part A Policy Pract. 2023, 173, 103702. [Google Scholar] [CrossRef] [Scilit]
- Pan, Y.; Cao, Z. Simulation Research on Traffic Flow Characteristics of Bus Stop Area Based on VISSIM Software. In Proceedings of the 2018 Prognostics and System Health Management Conference (PHM-Chongqing), Chongqing, China, 26–28 October 2018; pp. 1325–1330. [Google Scholar]
- Prakash, A.; Ravinder, R.; Vittalaiah, A.; Krishna Munipally, S.; Al-Farouni, M.H. VISSIM Based Traffic Flow Simulation Analysis on Road Network. E3S Web Conf. 2024, 529, 03009. [Google Scholar] [CrossRef] [Scilit]
- Ezquerro, S.; Alonso, B.; Moura, J.L. Sharing Bus Stops: An Efficient Use of Public Spaces. J. Clean. Prod. 2021, 294, 126282. [Google Scholar] [CrossRef] [Scilit]
- Zhou, X.; Xi, J.; Guan, Z.; Wei, G. Coordinated Control Method of Bus Signal Priority and Speed Adjustment Based on Stop-Skipping. Appl. Sci. 2023, 13, 4803. [Google Scholar] [CrossRef] [Scilit]
- Gu, W.; Li, Y.; Cassidy, M.J.; Griswold, J.B. On the Capacity of Isolated, Curbside Bus Stops. Transp. Res. Part B Methodol. 2011, 45, 714–723. [Google Scholar] [CrossRef] [Scilit]
- Yang, X.; Yang, X.; Pan, F.; Kang, Y.; Zhang, J. The Effect of Passenger Attributes on Alighting and Boarding Efficiency Based on Social Force Model. Phys. A Stat. Mech. Its Appl. 2021, 565, 125566. [Google Scholar] [CrossRef] [Scilit]
- Xue, Y.; Zhong, M.; Xue, L.; Zhang, B.; Tu, H.; Tan, C.; Kong, Q.; Guan, H. Simulation Analysis of Bus Passenger Boarding and Alighting Behavior Based on Cellular Automata. Sustainability 2022, 14, 2429. [Google Scholar] [CrossRef] [Scilit]
- Büchel, B.; Corman, F. Modelling Probability Distributions of Public Transport Travel Time Components. In Proceedings of the Swiss Transport Research Conference (STRC 2018), Ascona, Switzerland, 16–18 May 2018; ETH Zurich: Ascona, Switzerland, 2018. [Google Scholar]
- Luo, T.; Liu, X.; Jin, H. Bus Queue Time Estimation Model for a Curbside Bus Stop Considering the Blocking Effect. Sci. Rep. 2022, 12, 11576. [Google Scholar] [CrossRef] [Scilit]
- Fernández, R.; Valencia, A.; Seriani, S. On Passenger Saturation Flow in Public Transport Doors. Transp. Res. Part A Policy Pract. 2015, 78, 102–112. [Google Scholar] [CrossRef] [Scilit]
- Stępień, J. A Fuzzy Logic-Based Car-Following Model for Simulating Transit Vehicle Movement at and Around Bus Stop Used by Various Users. Arch. Transp. 2025, 75, 93–140. [Google Scholar] [CrossRef] [Scilit]
- Singer, S.; Singer, S. Efficient Implementation of the Nelder–Mead Search Algorithm. Appl. Numer. Anal. Comput. Math. 2004, 1, 524–534. [Google Scholar] [CrossRef] [Scilit]
- Xu, C.; Gao, J.; Zuo, F.; Ozbay, K. Estimating Urban Traffic Safety and Analyzing Spatial Patterns through the Integration of City-Wide Near-Miss Data: A New York City Case Study. Appl. Sci. 2024, 14, 6378. [Google Scholar] [CrossRef] [Scilit]
- Choulakian, V.; Lockhart, R.A.; Stephens, M.A. Cramér-von Mises Statistics for Discrete Distributions. Can. J. Stat. 1994, 22, 125–137. [Google Scholar] [CrossRef] [Scilit]
- Marsaglia, G.; Marsaglia, J. Evaluating the Anderson-Darling Distribution. J. Stat. Softw. 2004, 9, 1–4. [Google Scholar] [CrossRef] [Scilit]
- Crawley, M.J. The R Book; Wiley: Hoboken, NJ, USA, 2012; ISBN 9780470973929. [Google Scholar]
- Miller, A. Subset Selection in Regression; Chapman and Hall/CRC: Boca Raton, FL, USA, 2002; ISBN 9780429119187. [Google Scholar]
- Neath, A.A.; Cavanaugh, J.E. The Bayesian Information Criterion: Background, Derivation, and Applications. WIREs Comput. Stat. 2012, 4, 199–203. [Google Scholar] [CrossRef] [Scilit]
- Briant, S.; Cushing, D.; Washington, T.; Swart, M. Small but Significant: A Review of Research on the Potential of Bus Shelters as Resilient Infrastructure. Appl. Sci. 2025, 15, 6724. [Google Scholar] [CrossRef] [Scilit]
- Pan, Y.; Li, S.; Tang, X. Investigation of Bus Shelters and Their Thermal Environment in Hot–Humid Areas—A Case Study in Guangzhou. Buildings 2024, 14, 2377. [Google Scholar] [CrossRef] [Scilit]
- Corazza, M.V.; Favaretto, N. A Methodology to Evaluate Accessibility to Bus Stops as a Contribution to Improve Sustainability in Urban Mobility. Sustainability 2019, 11, 803. [Google Scholar] [CrossRef] [Scilit]
- Santos, T.; Lobato, K.; Rocha, J.; Tenedório, J.A. Modeling Photovoltaic Potential for Bus Shelters on a City-Scale: A Case Study in Lisbon. Appl. Sci. 2020, 10, 4801. [Google Scholar] [CrossRef] [Scilit]
- Phillips, R.O.; Hagen, O.H.; Berge, S.H. Bus Stop Design and Traffic Safety: An Explorative Analysis. Accid. Anal. Prev. 2021, 153, 105917. [Google Scholar] [CrossRef] [Scilit] [PubMed]
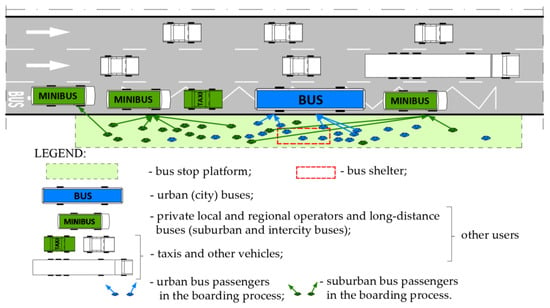
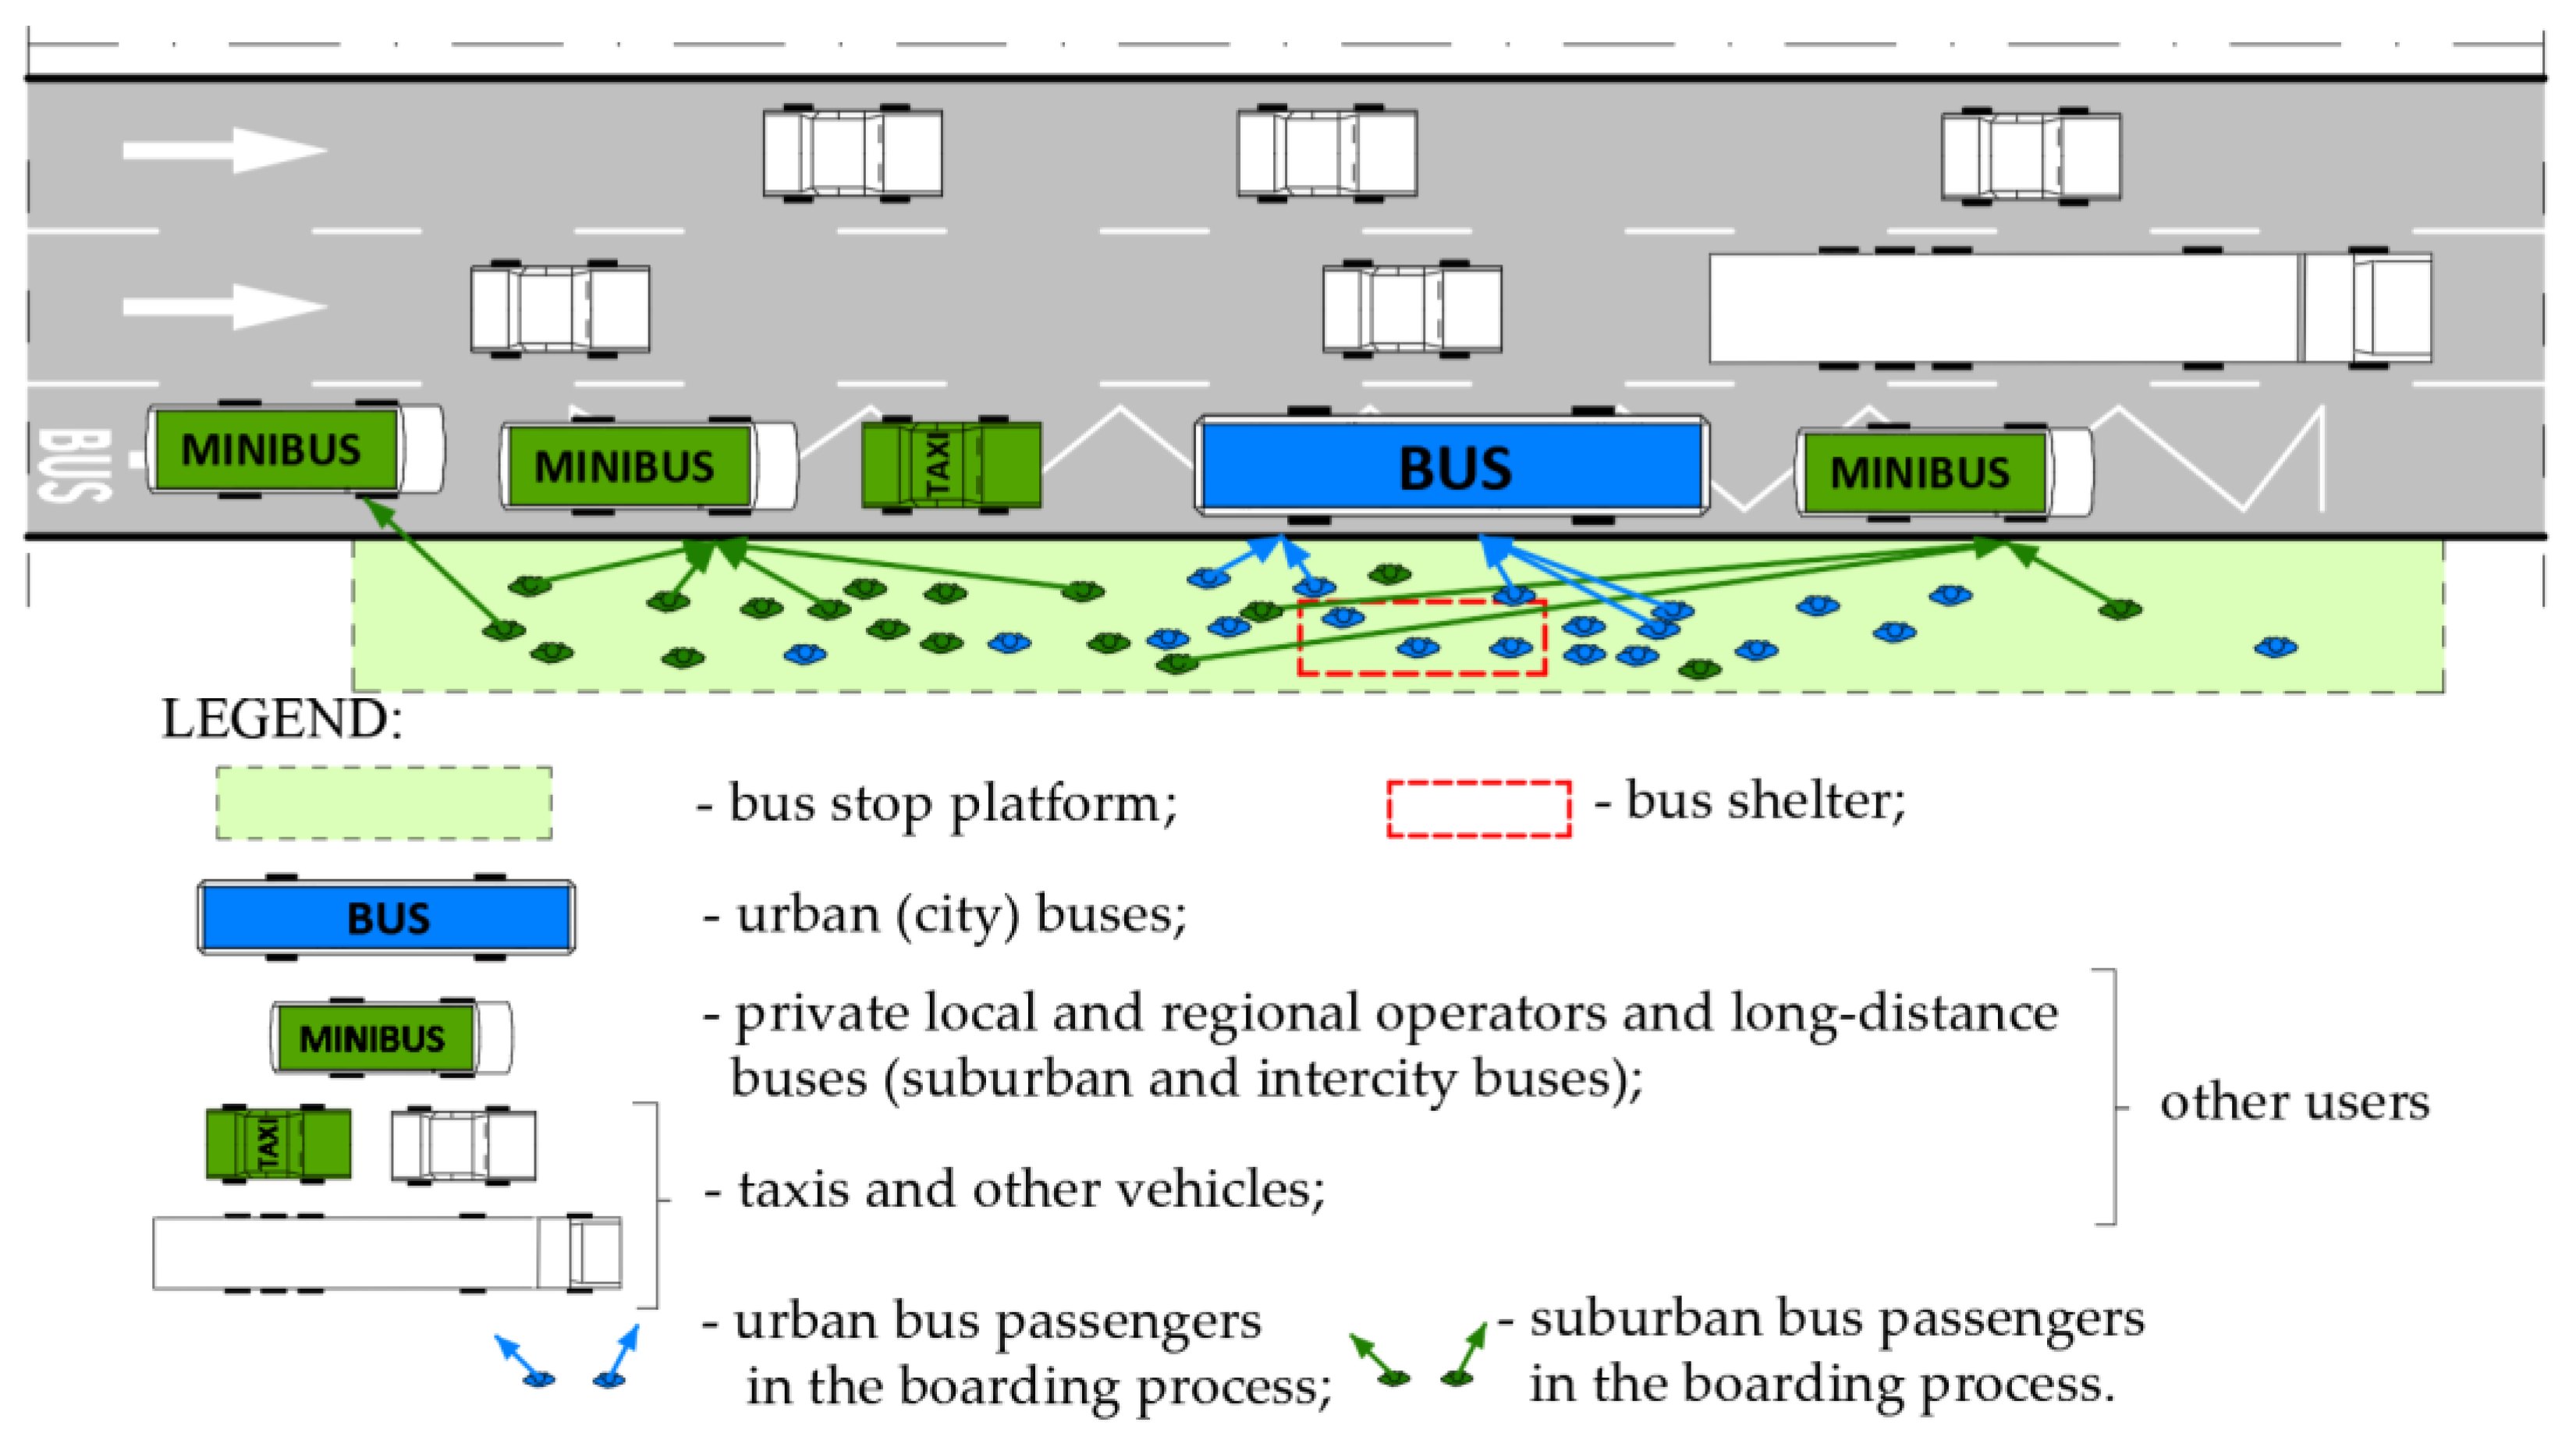
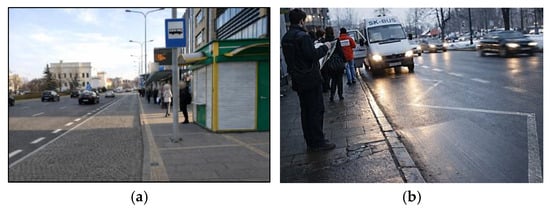
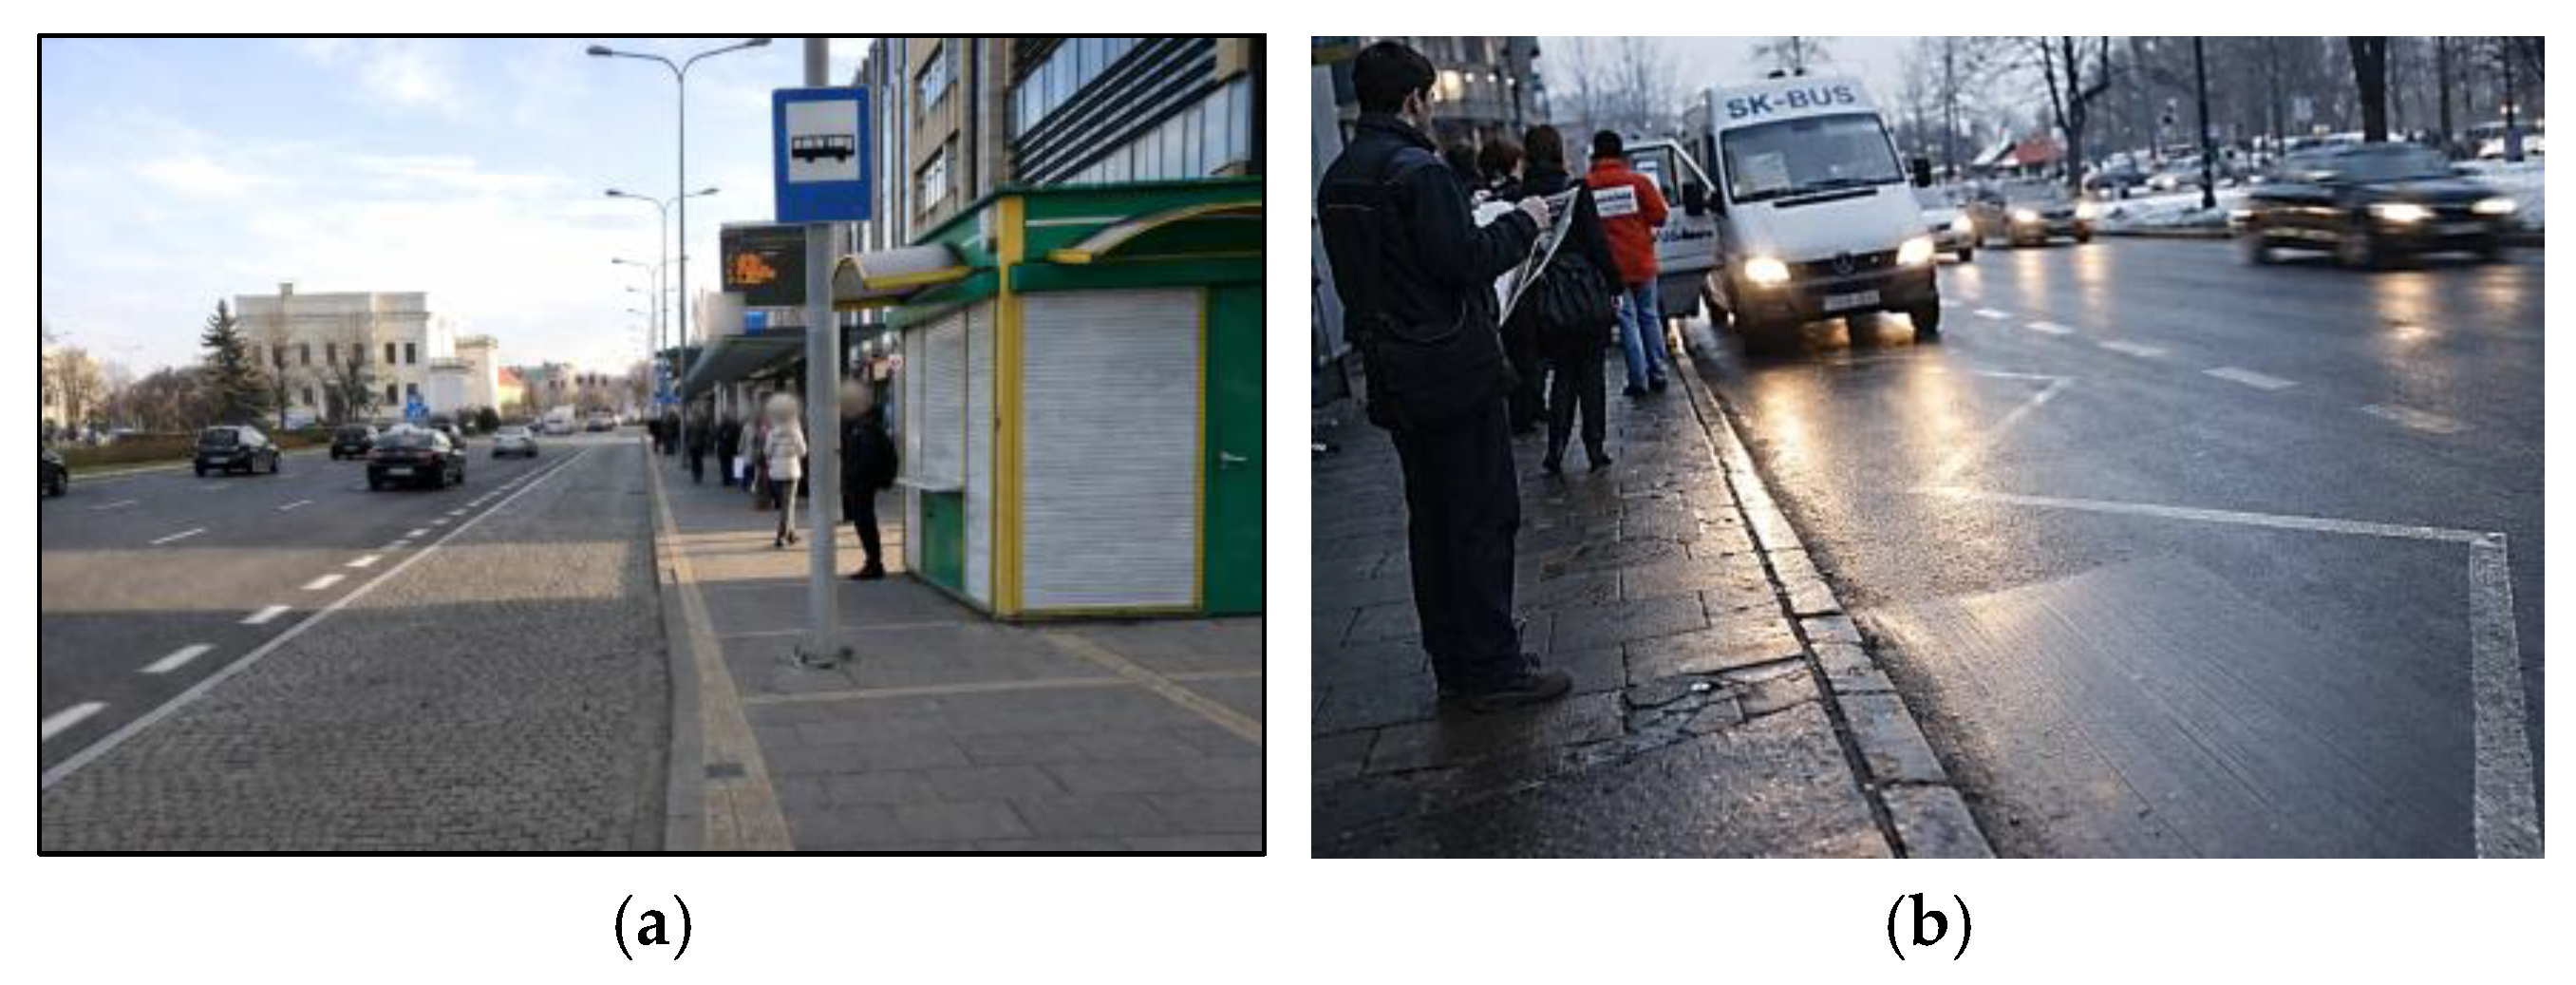
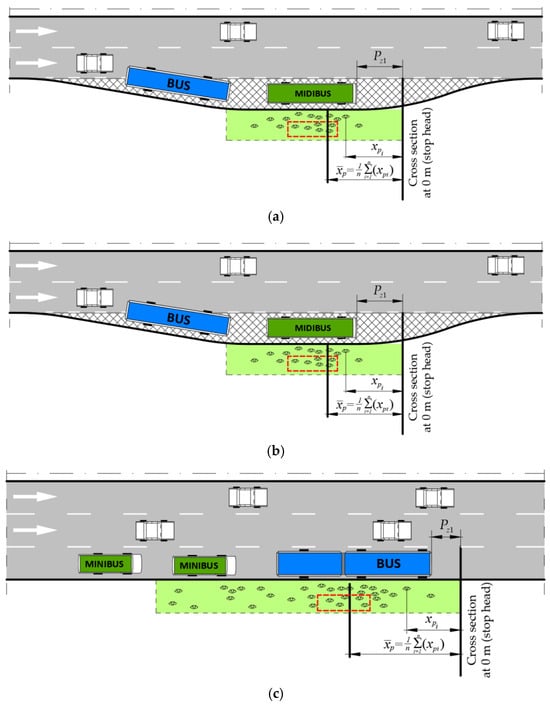
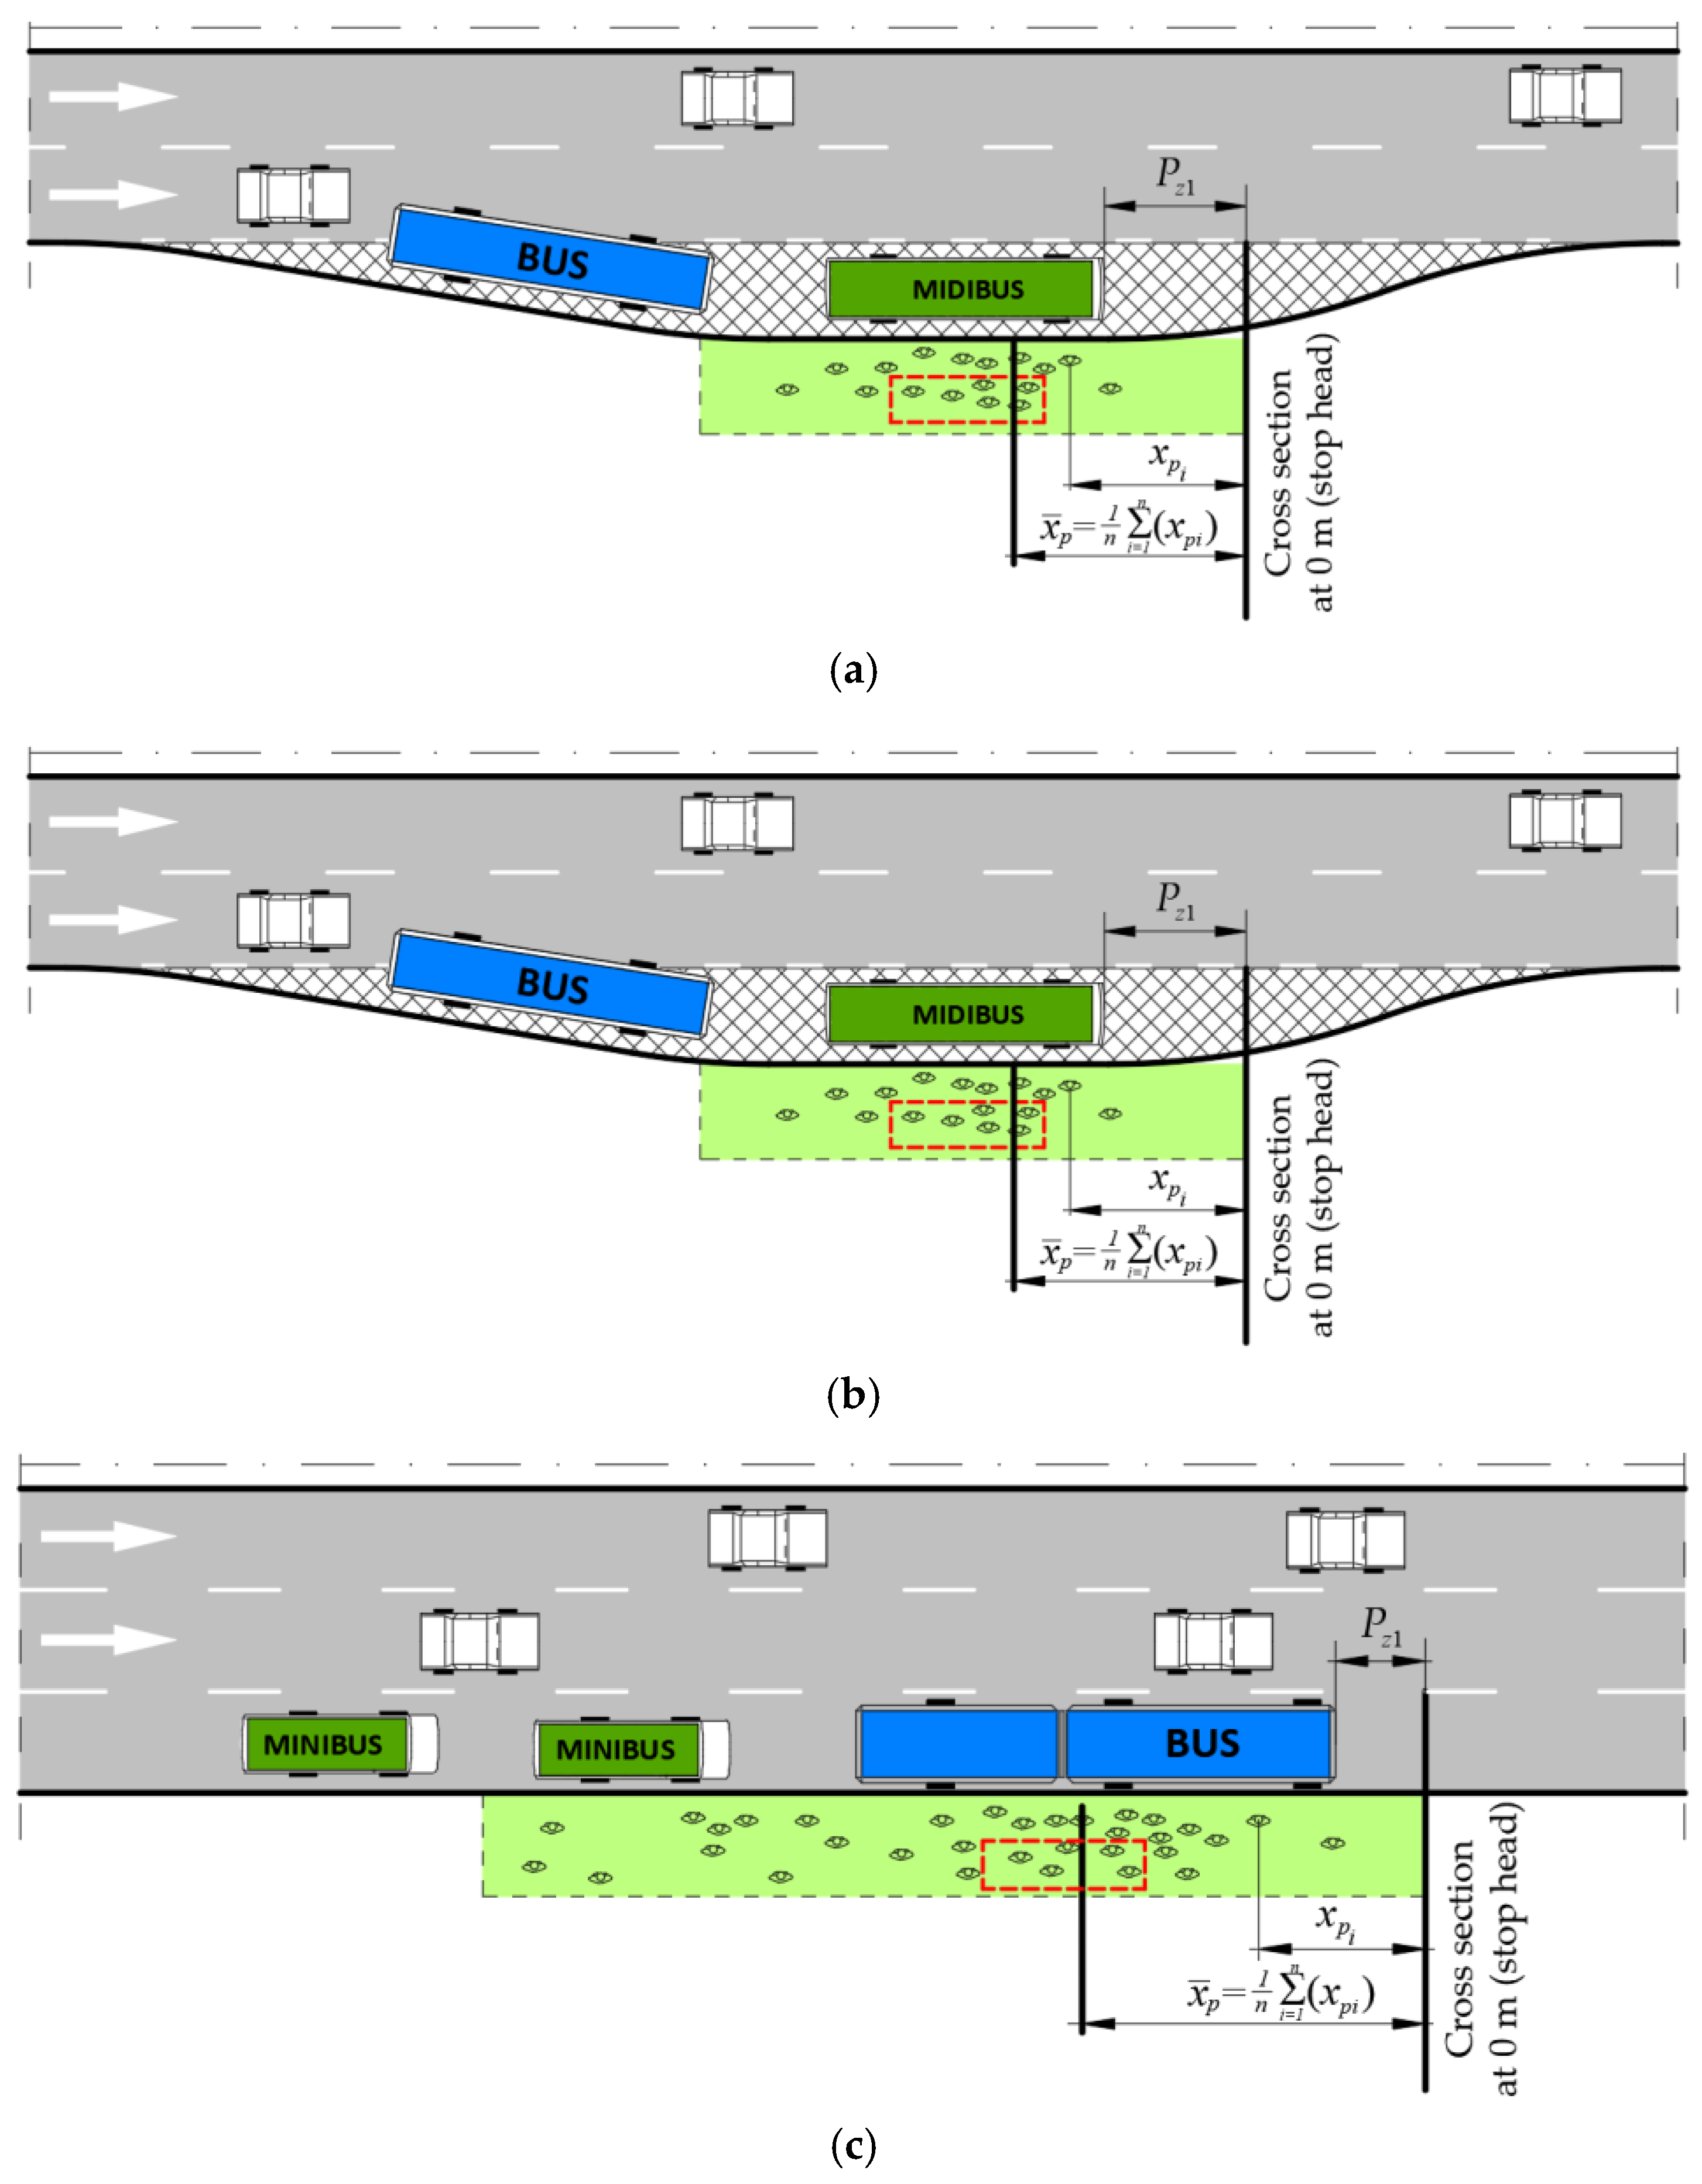
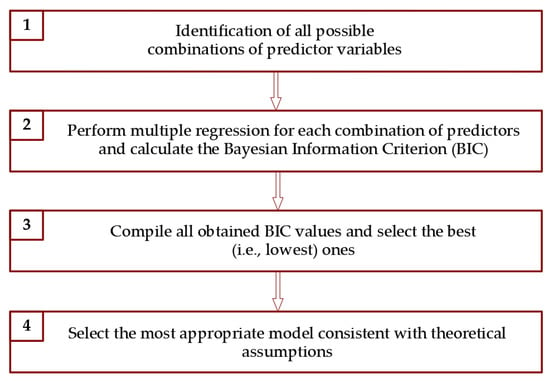
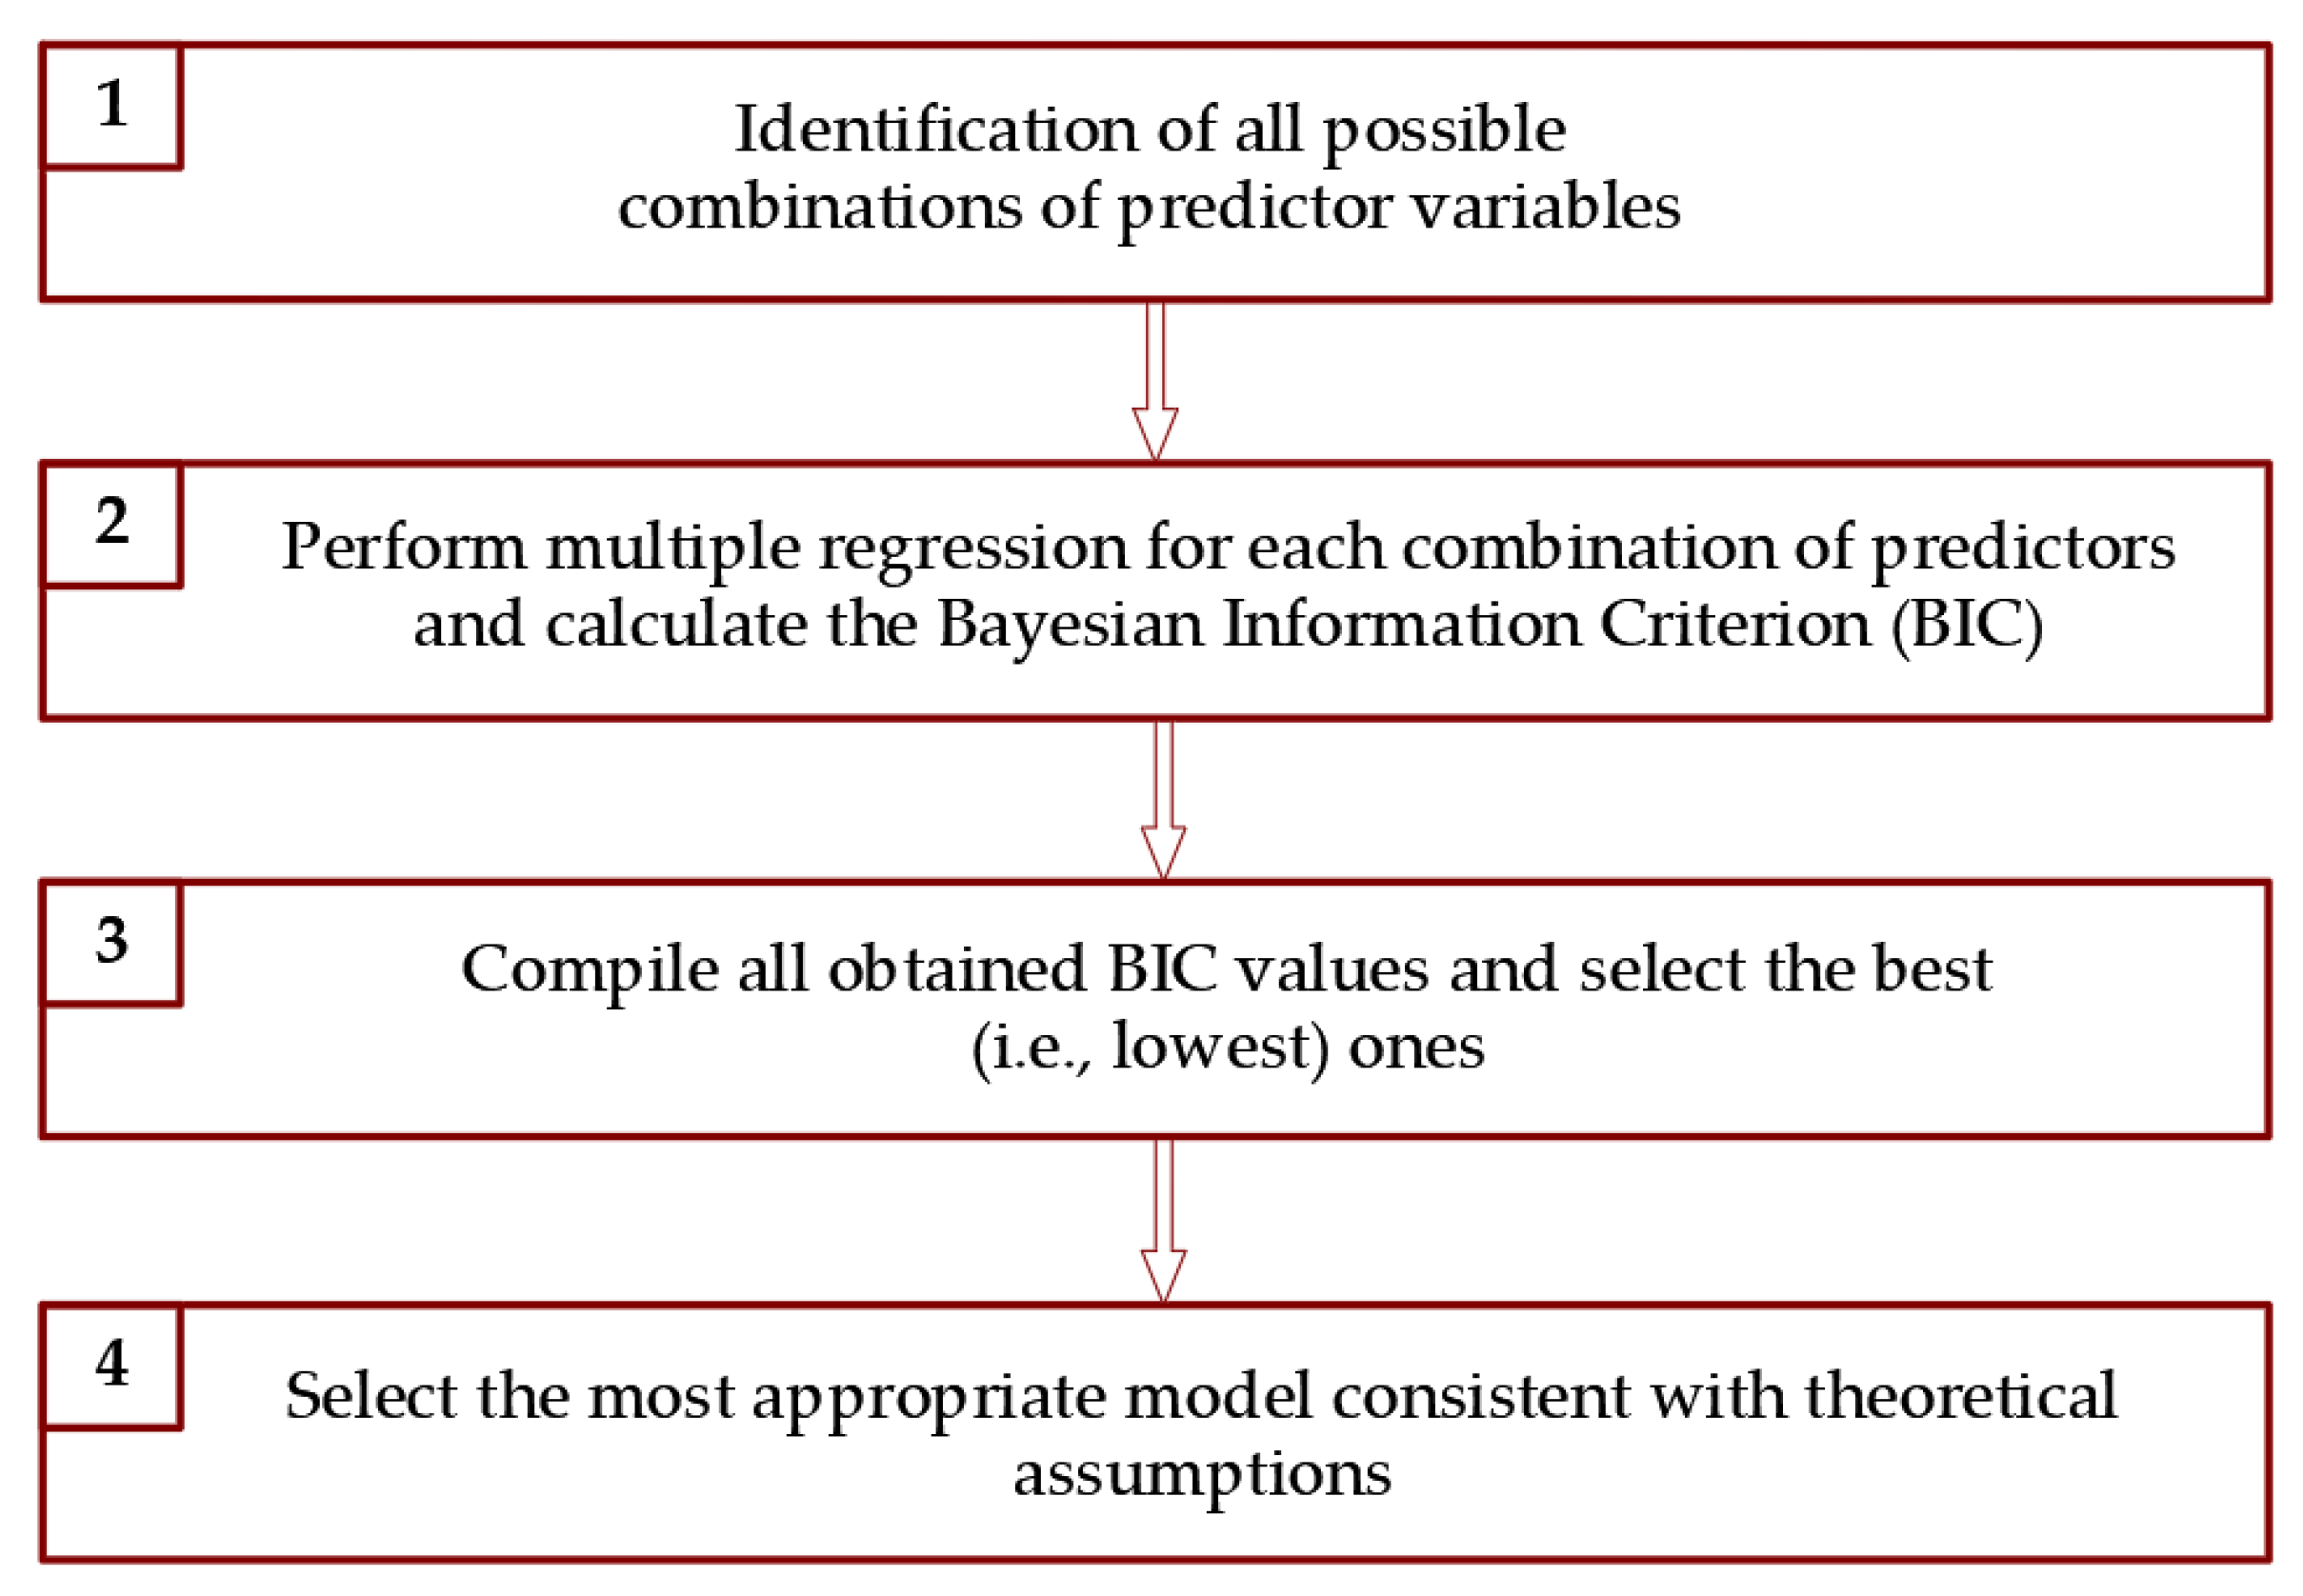
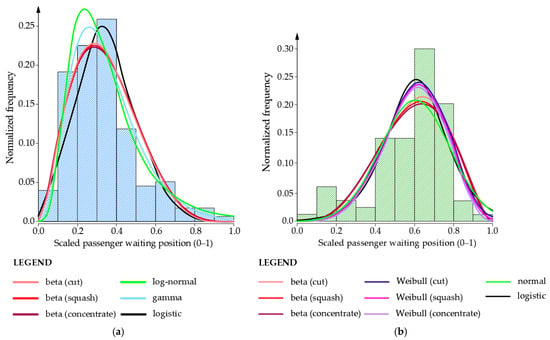
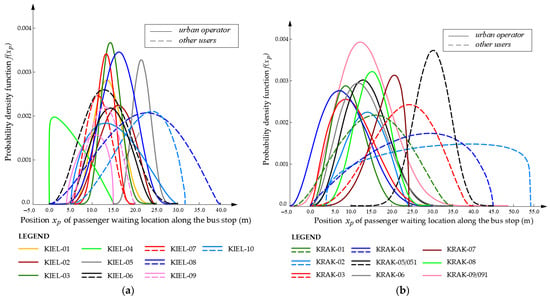
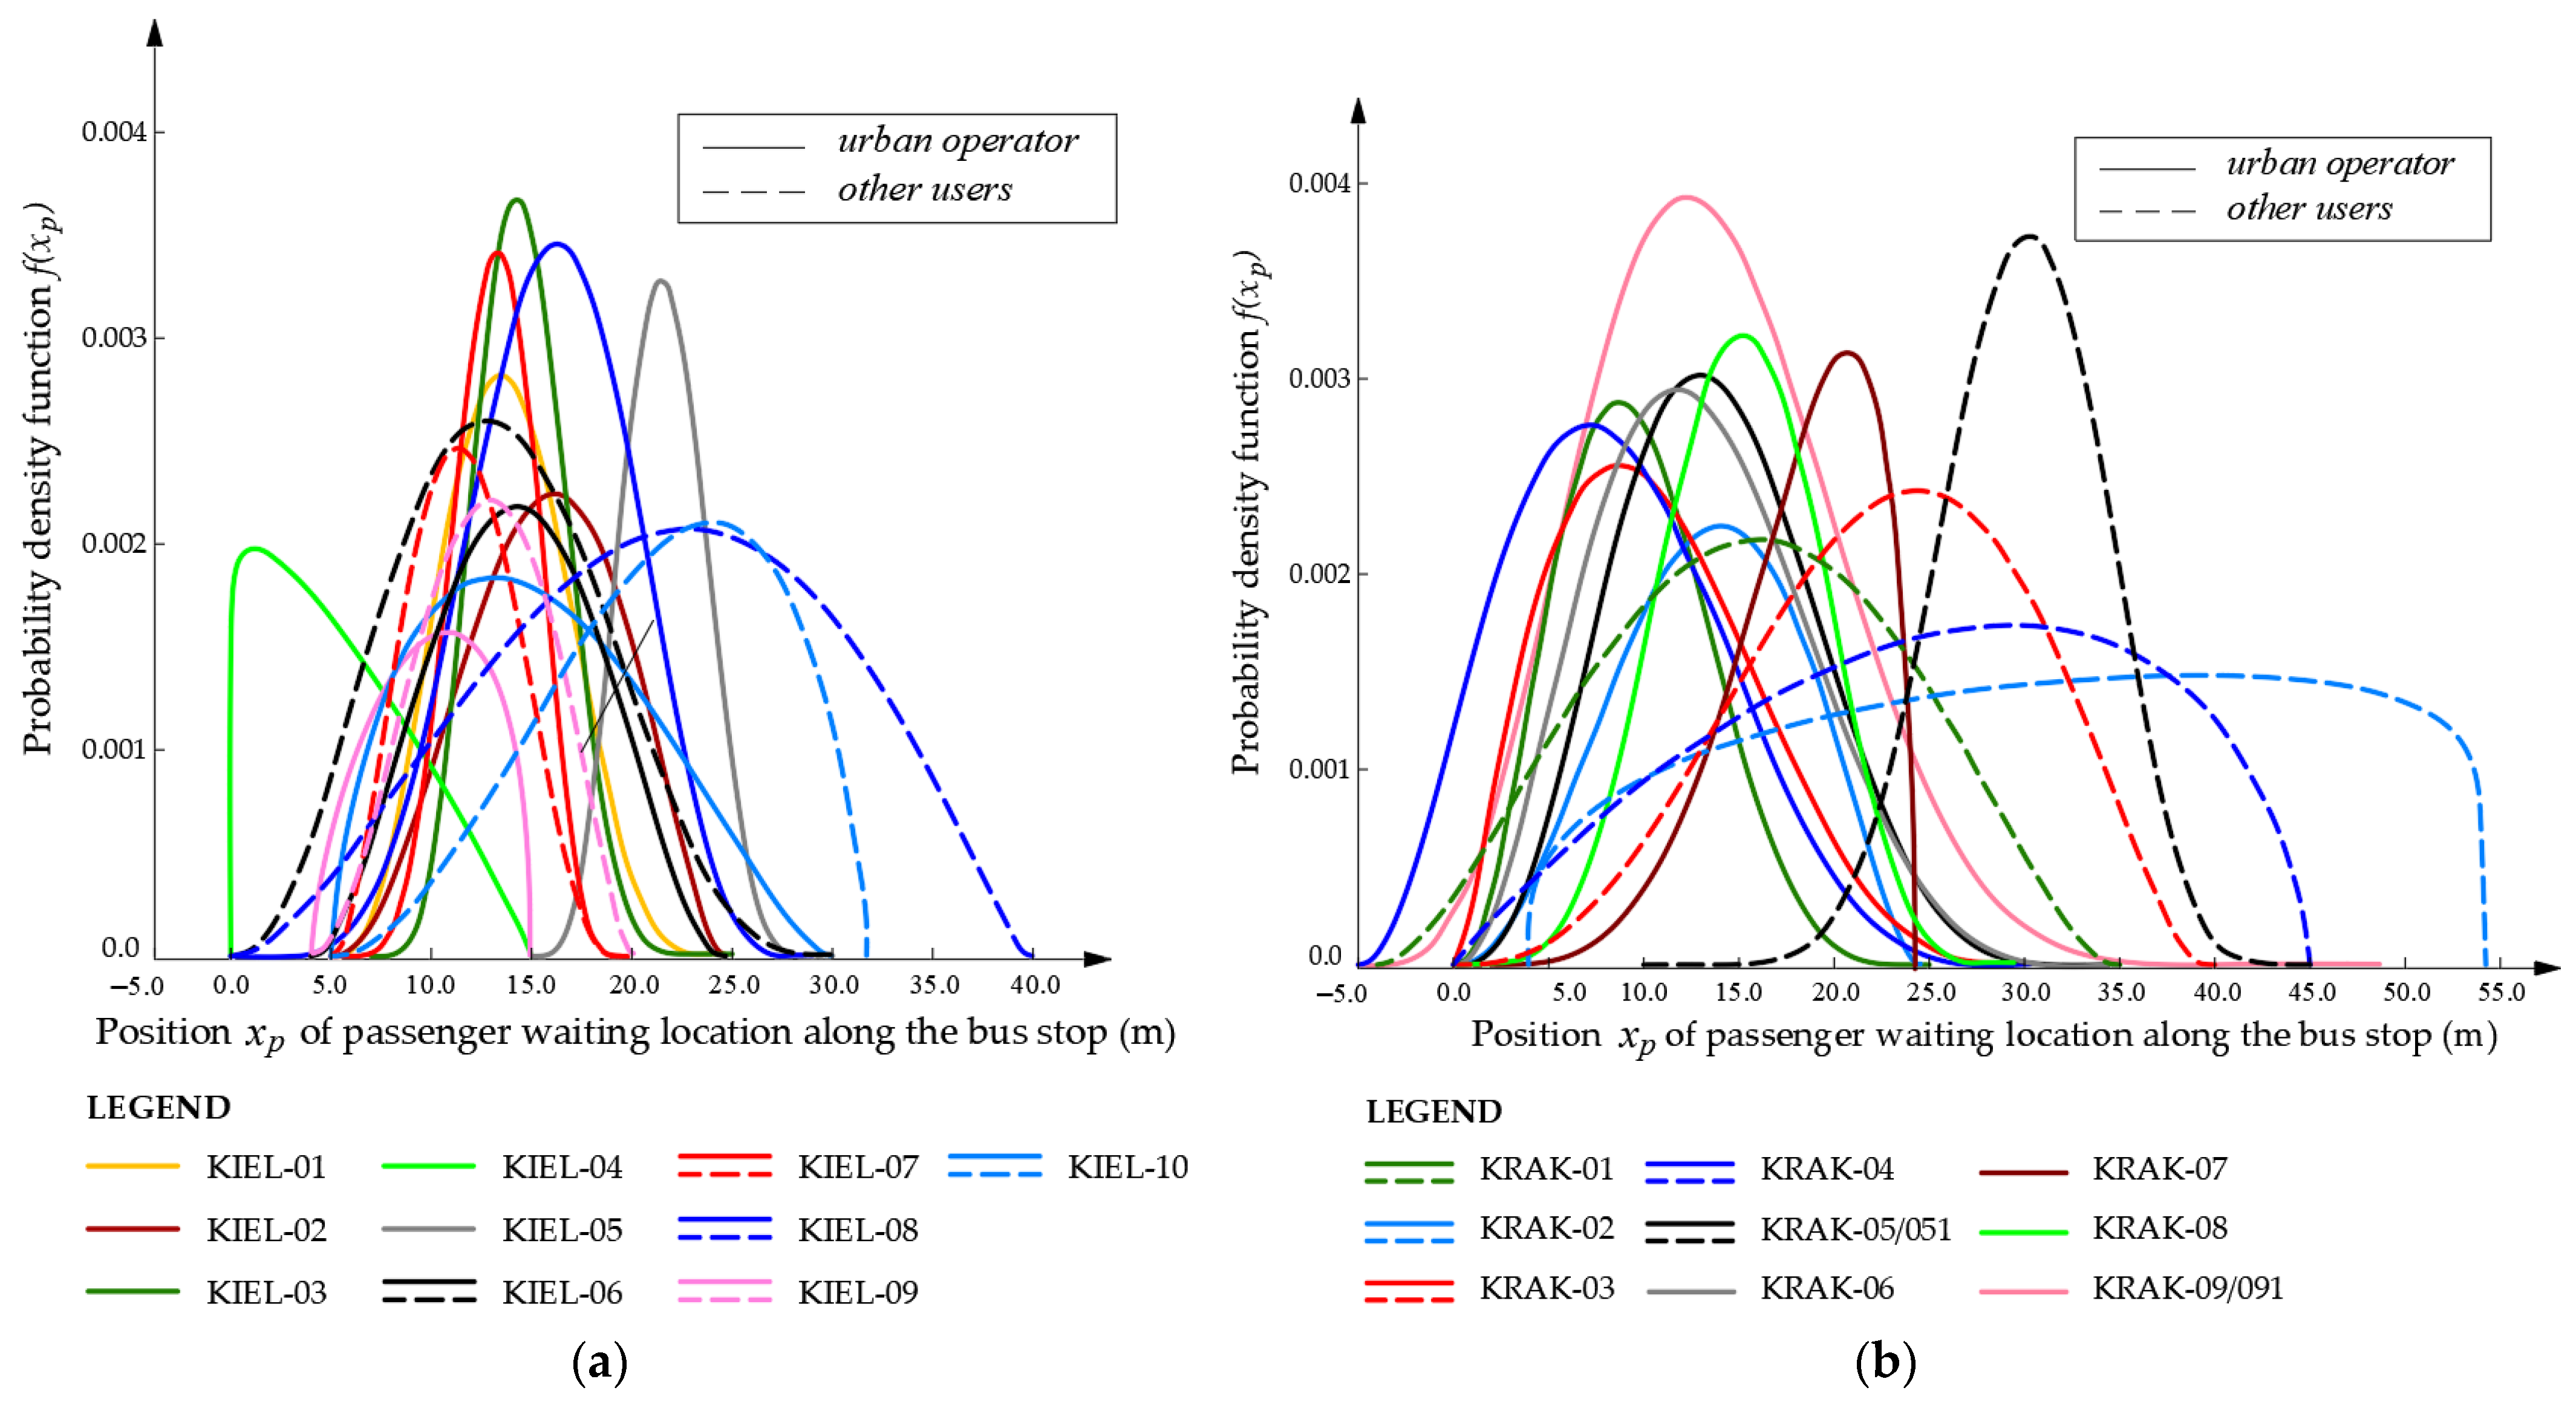
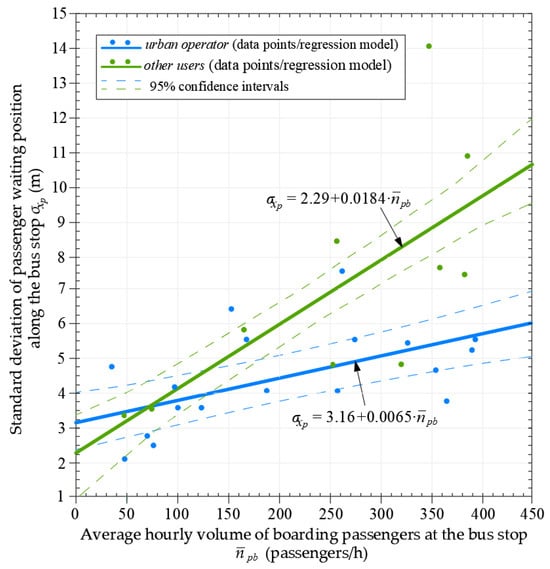
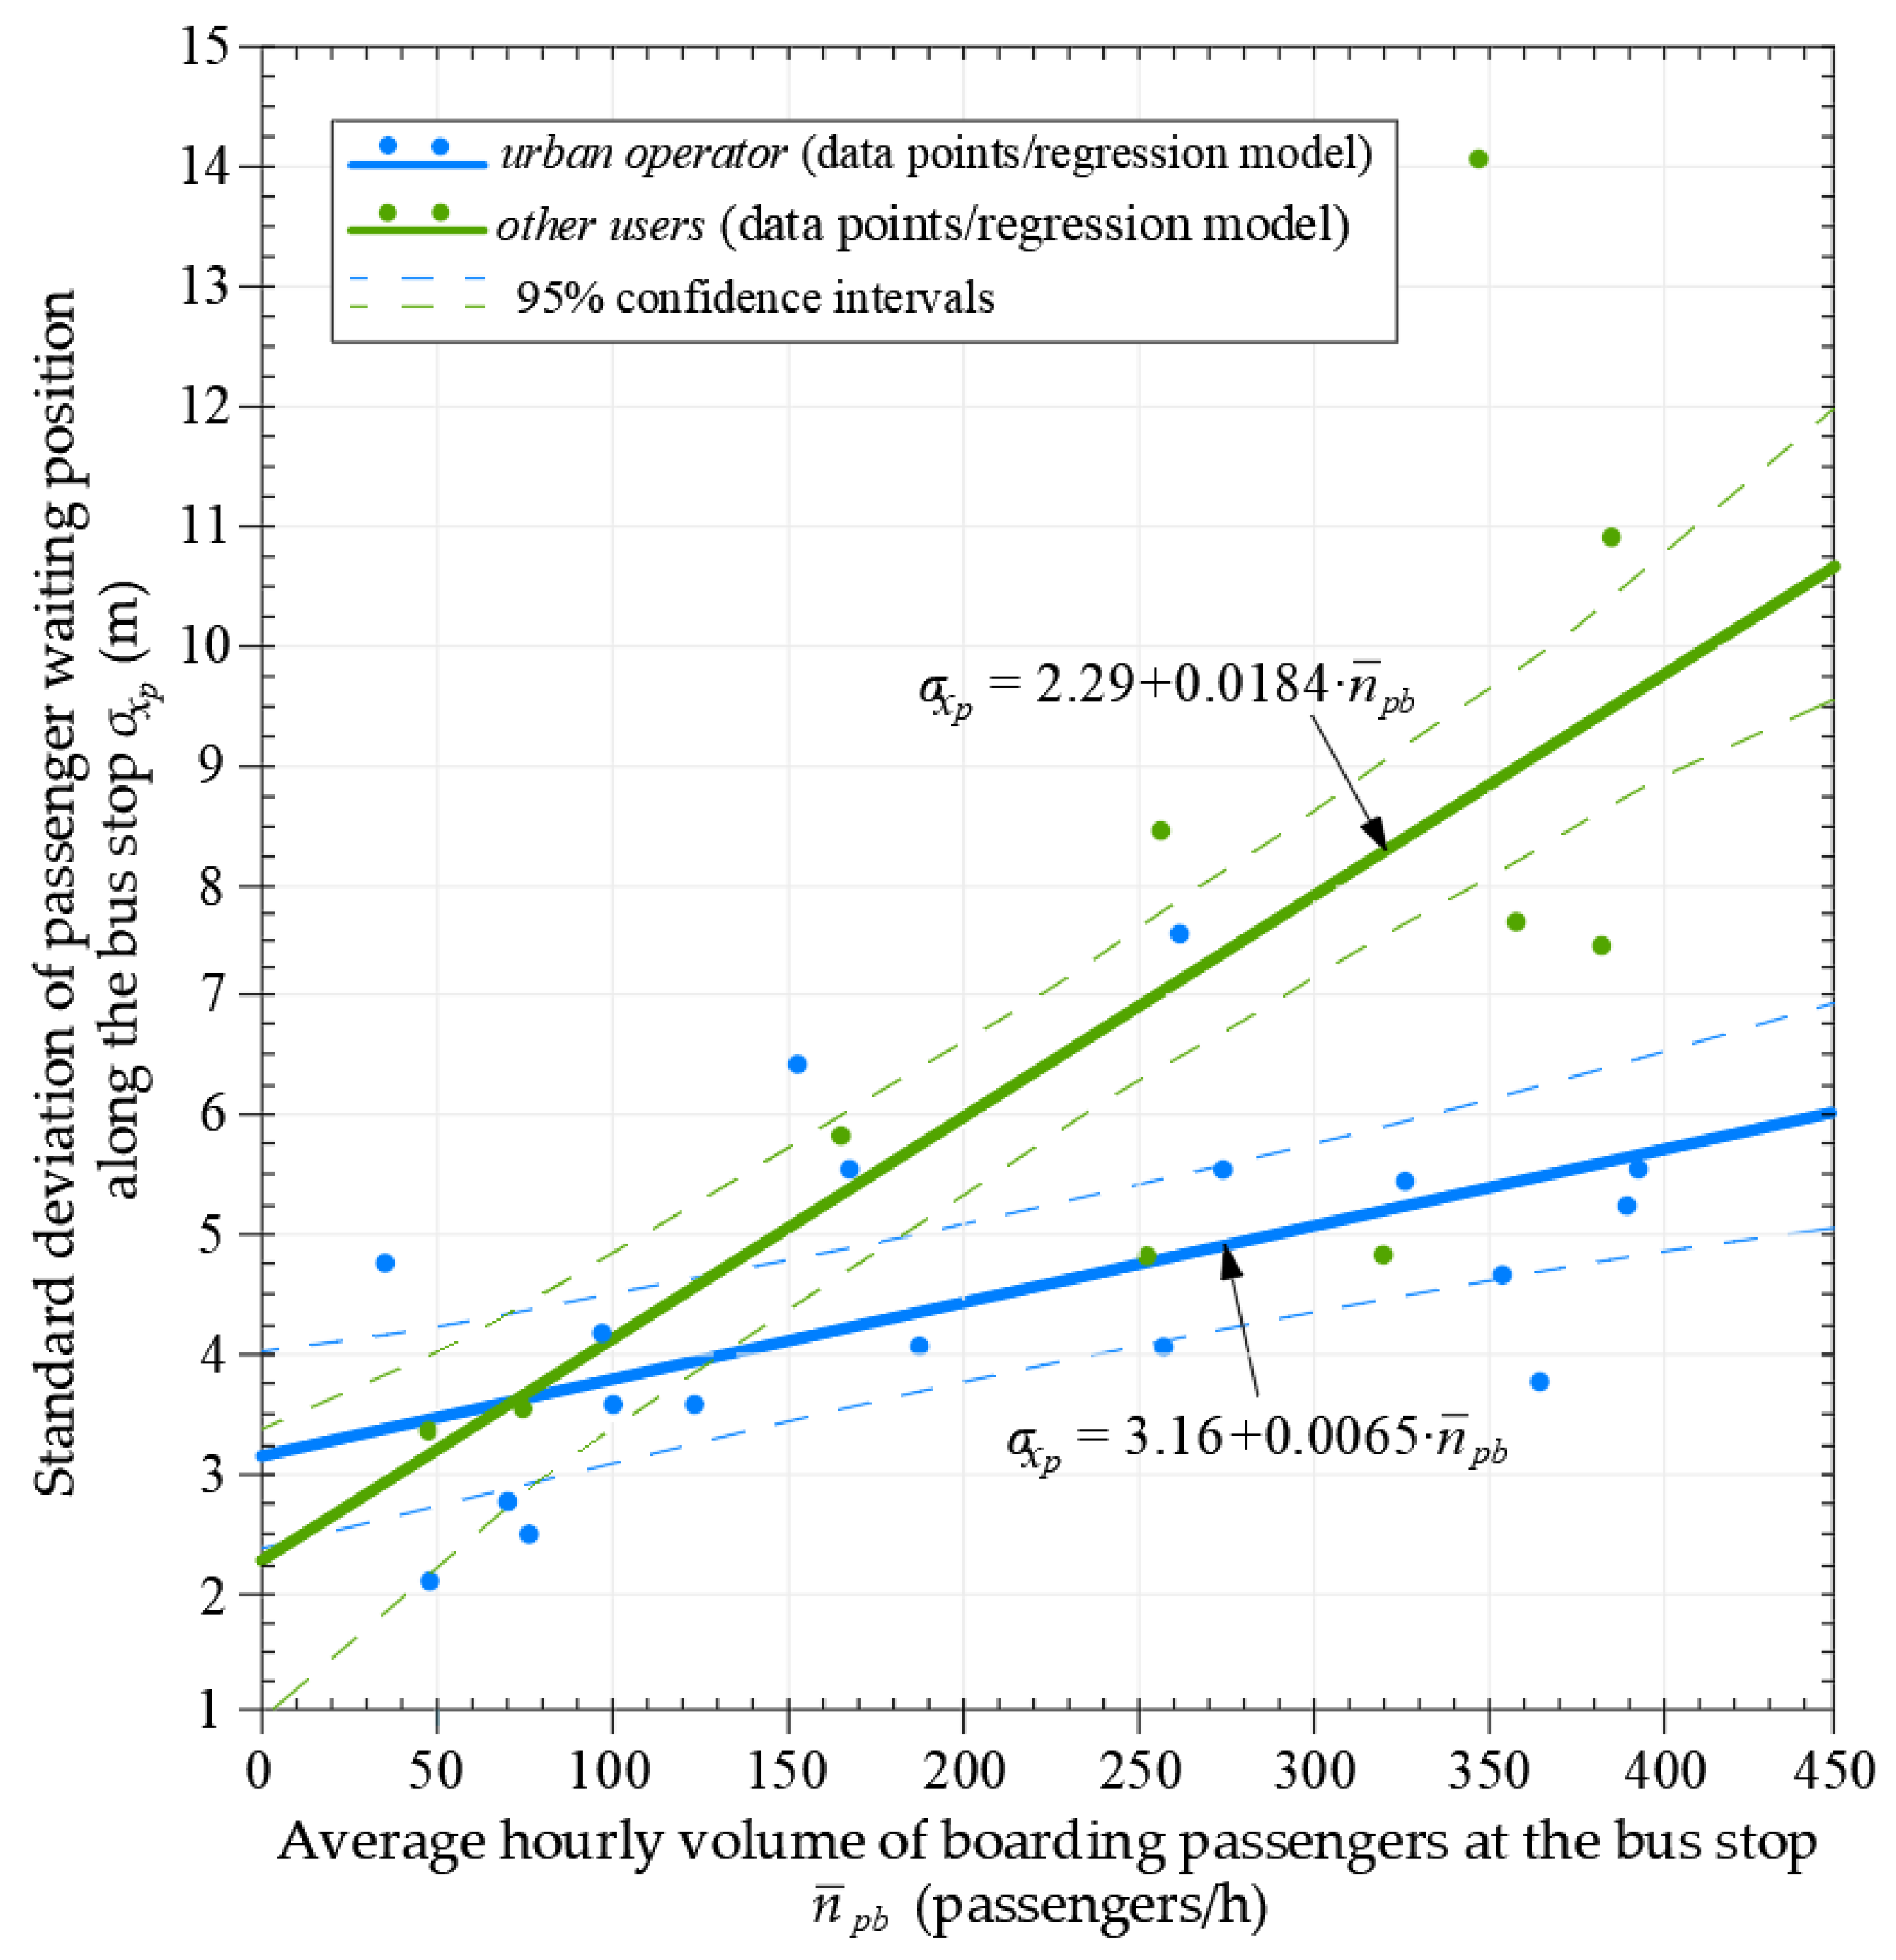
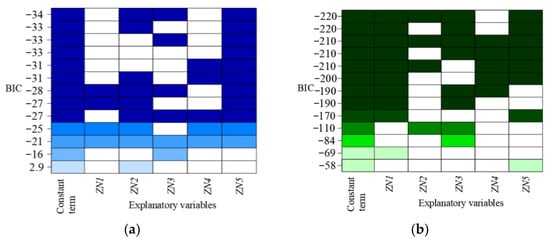
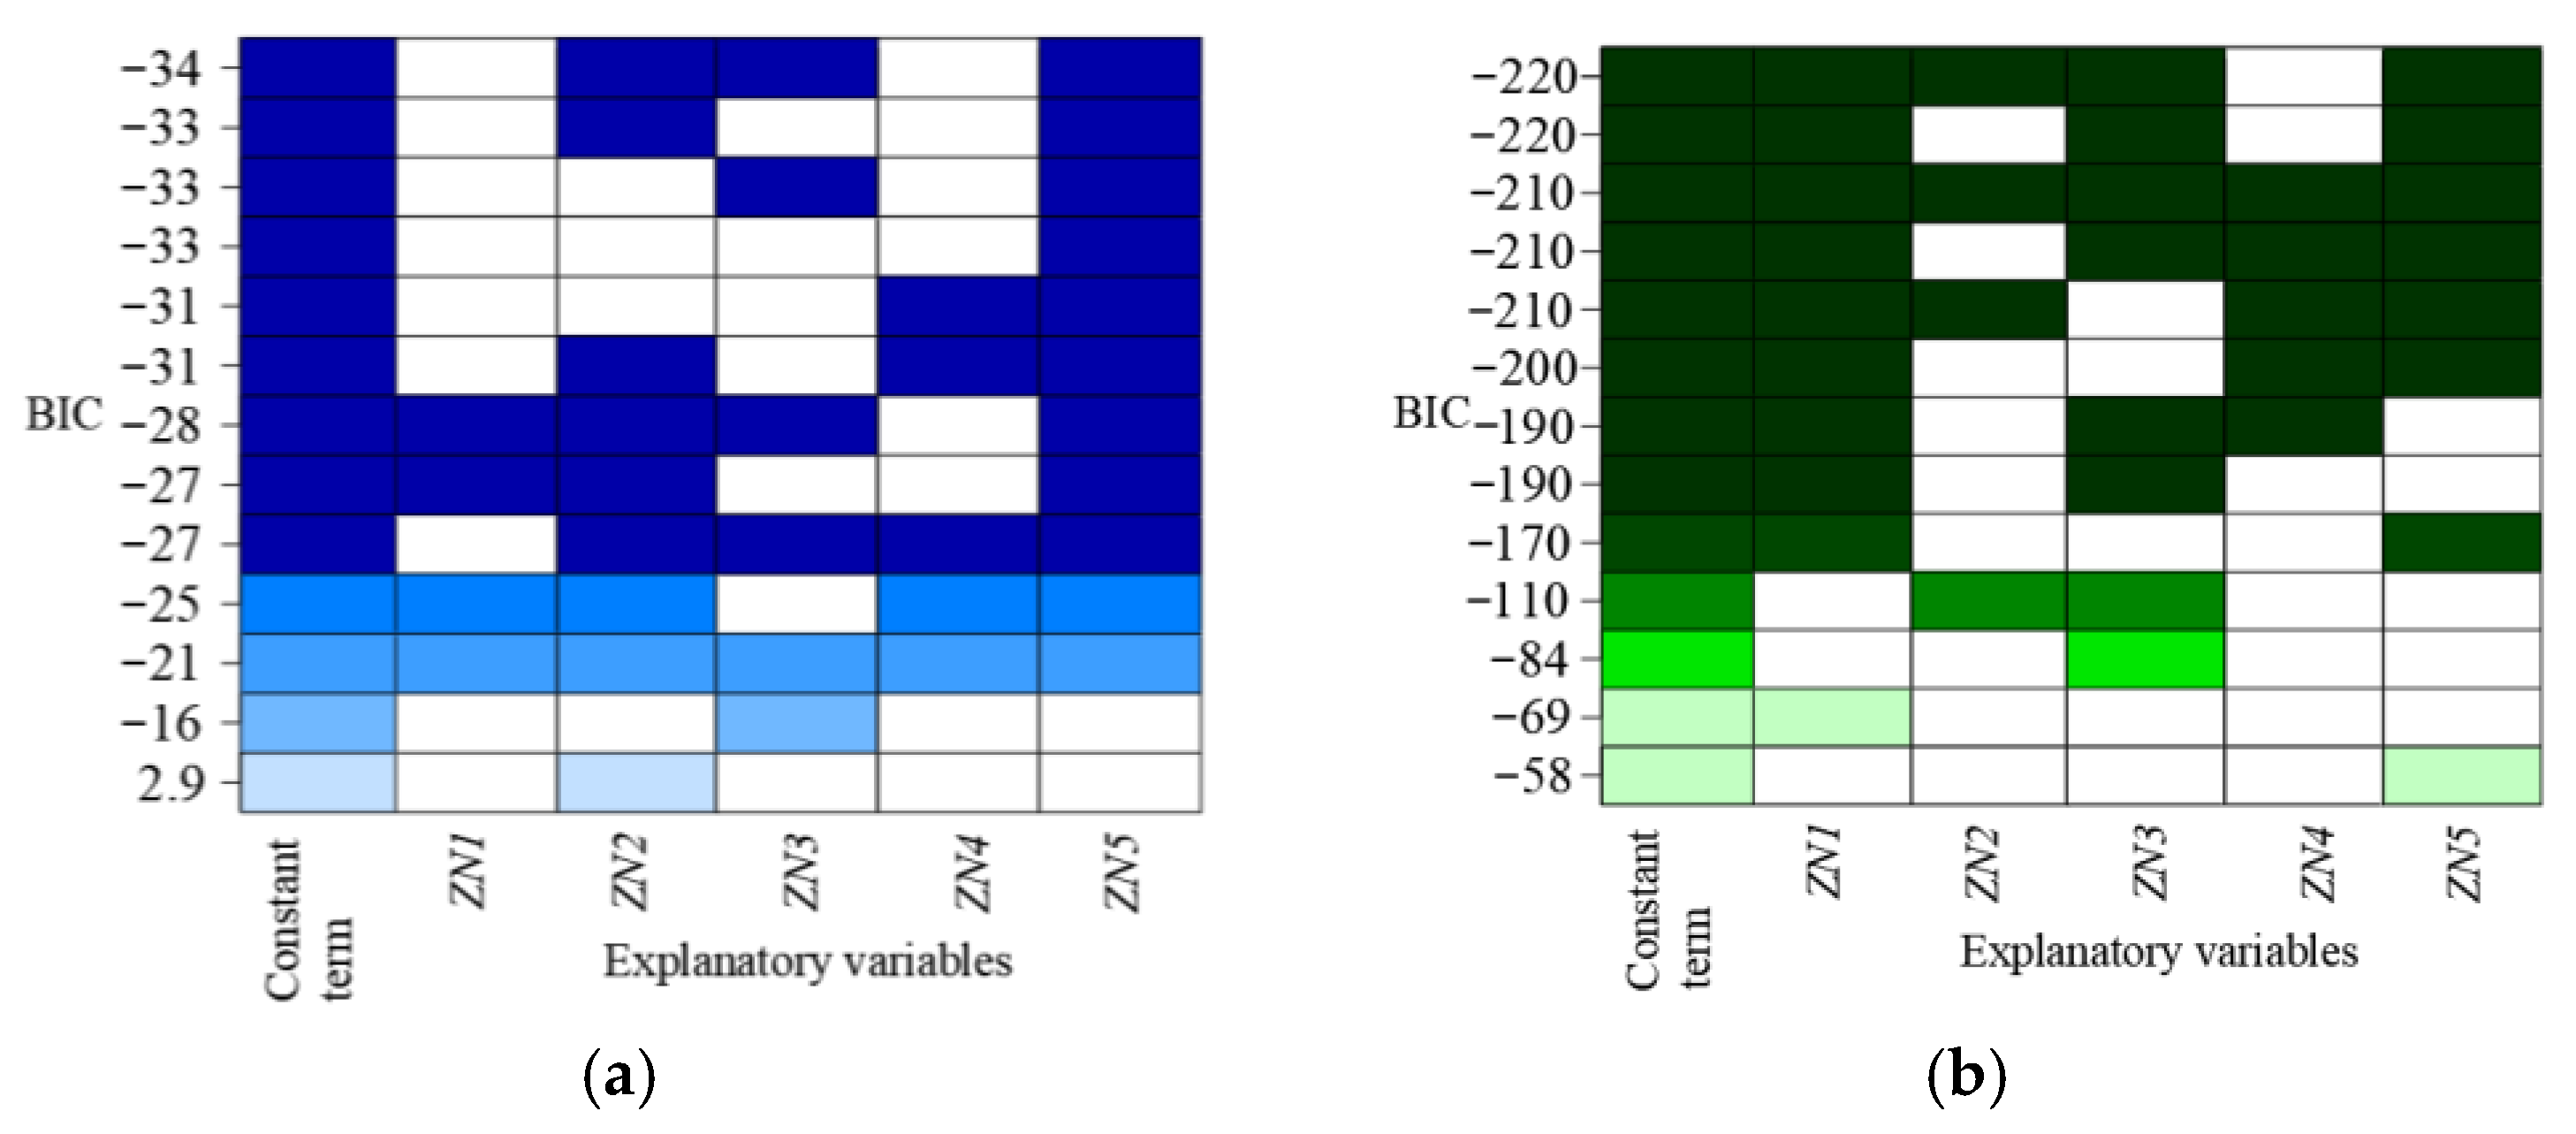
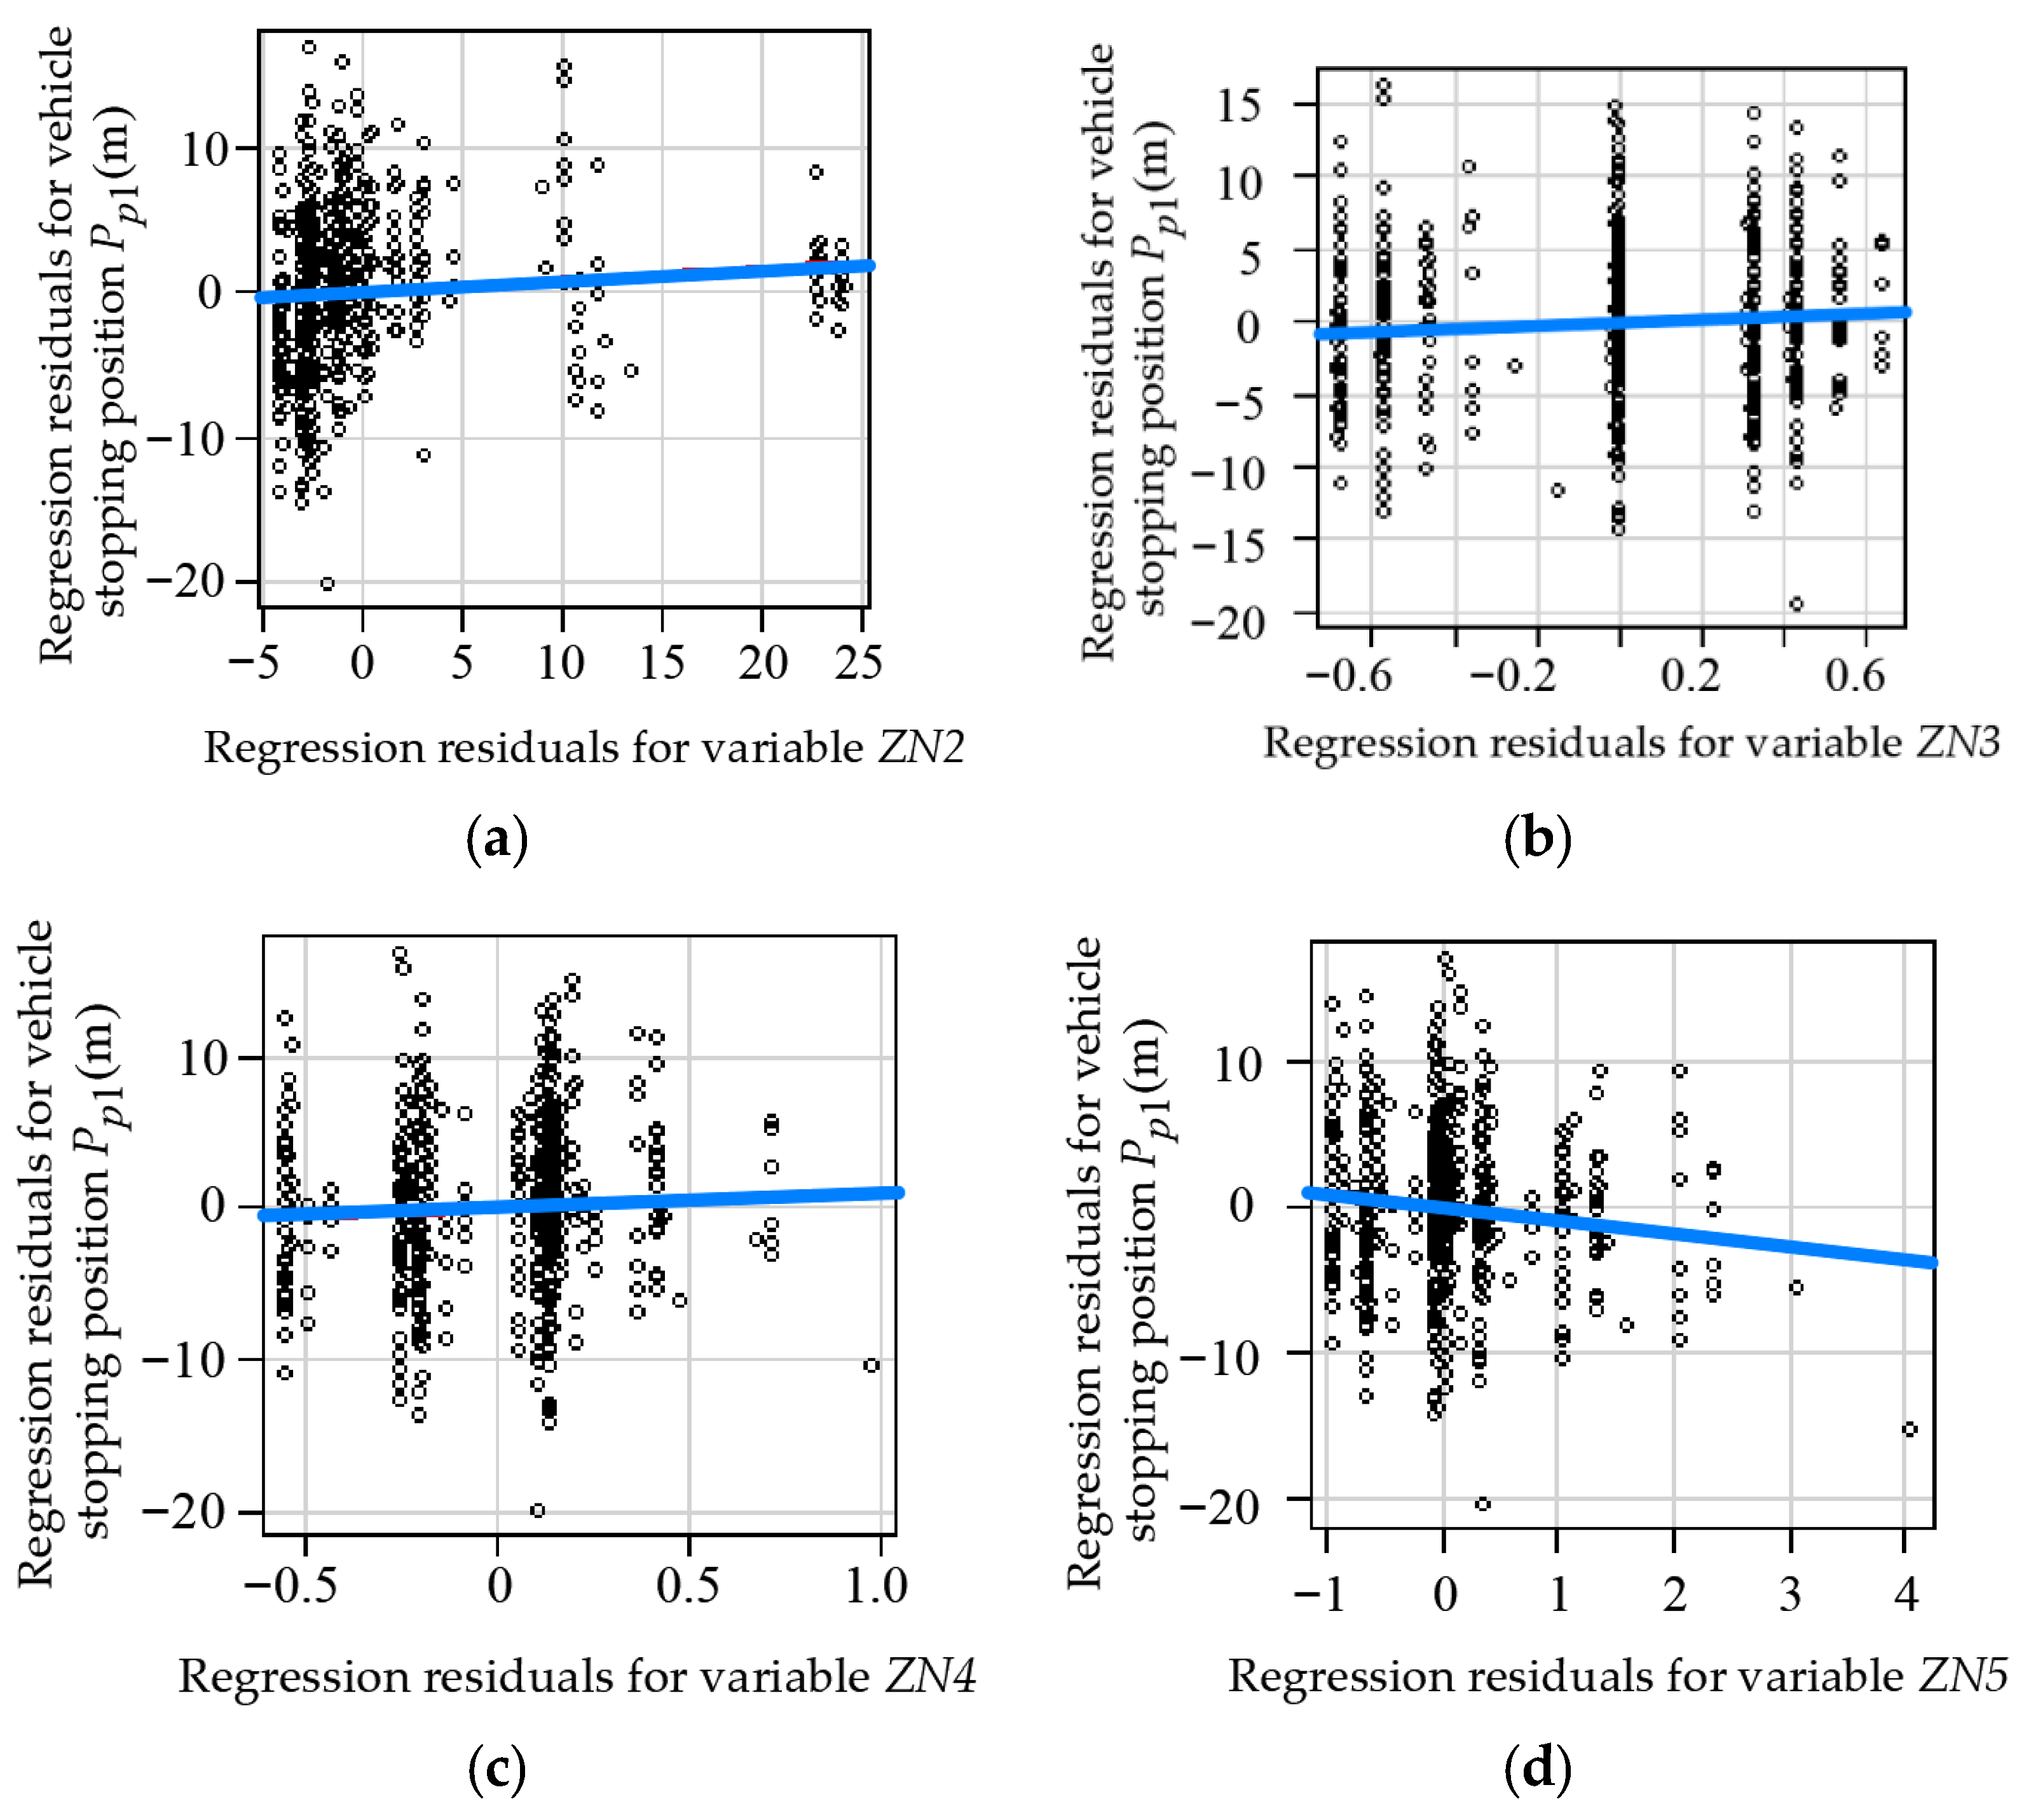
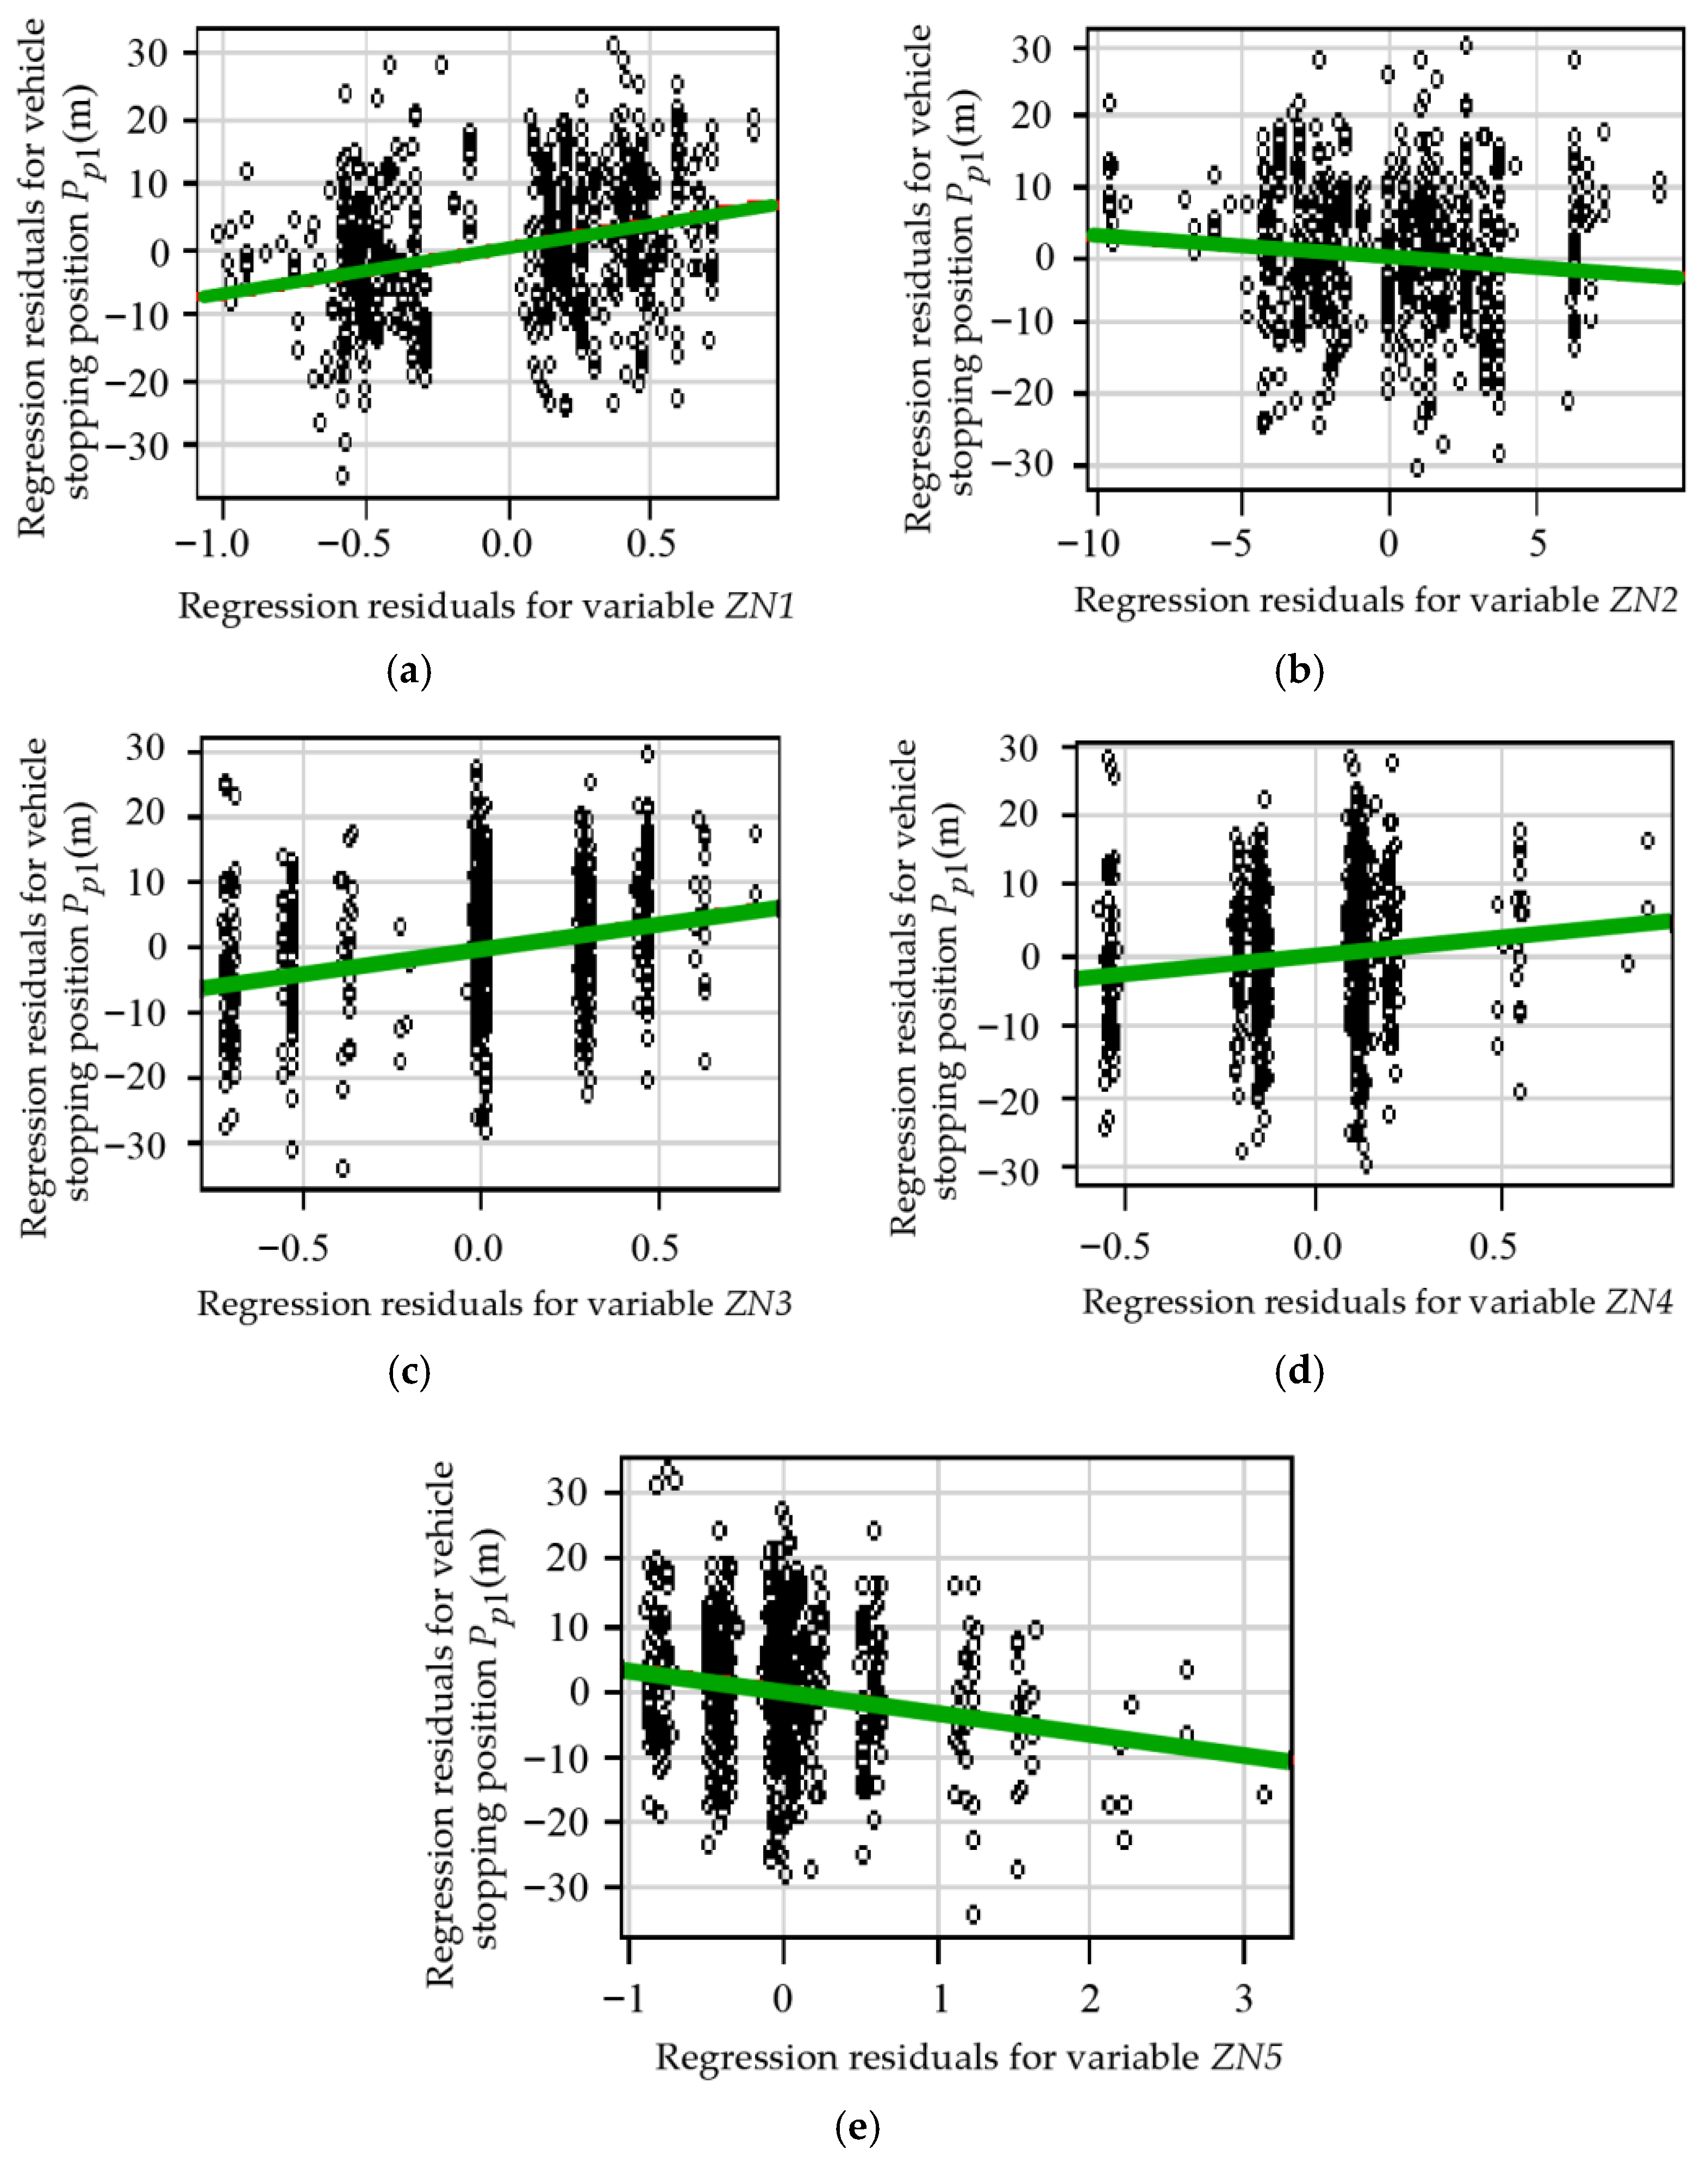
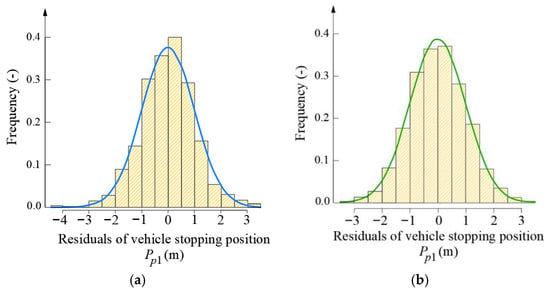
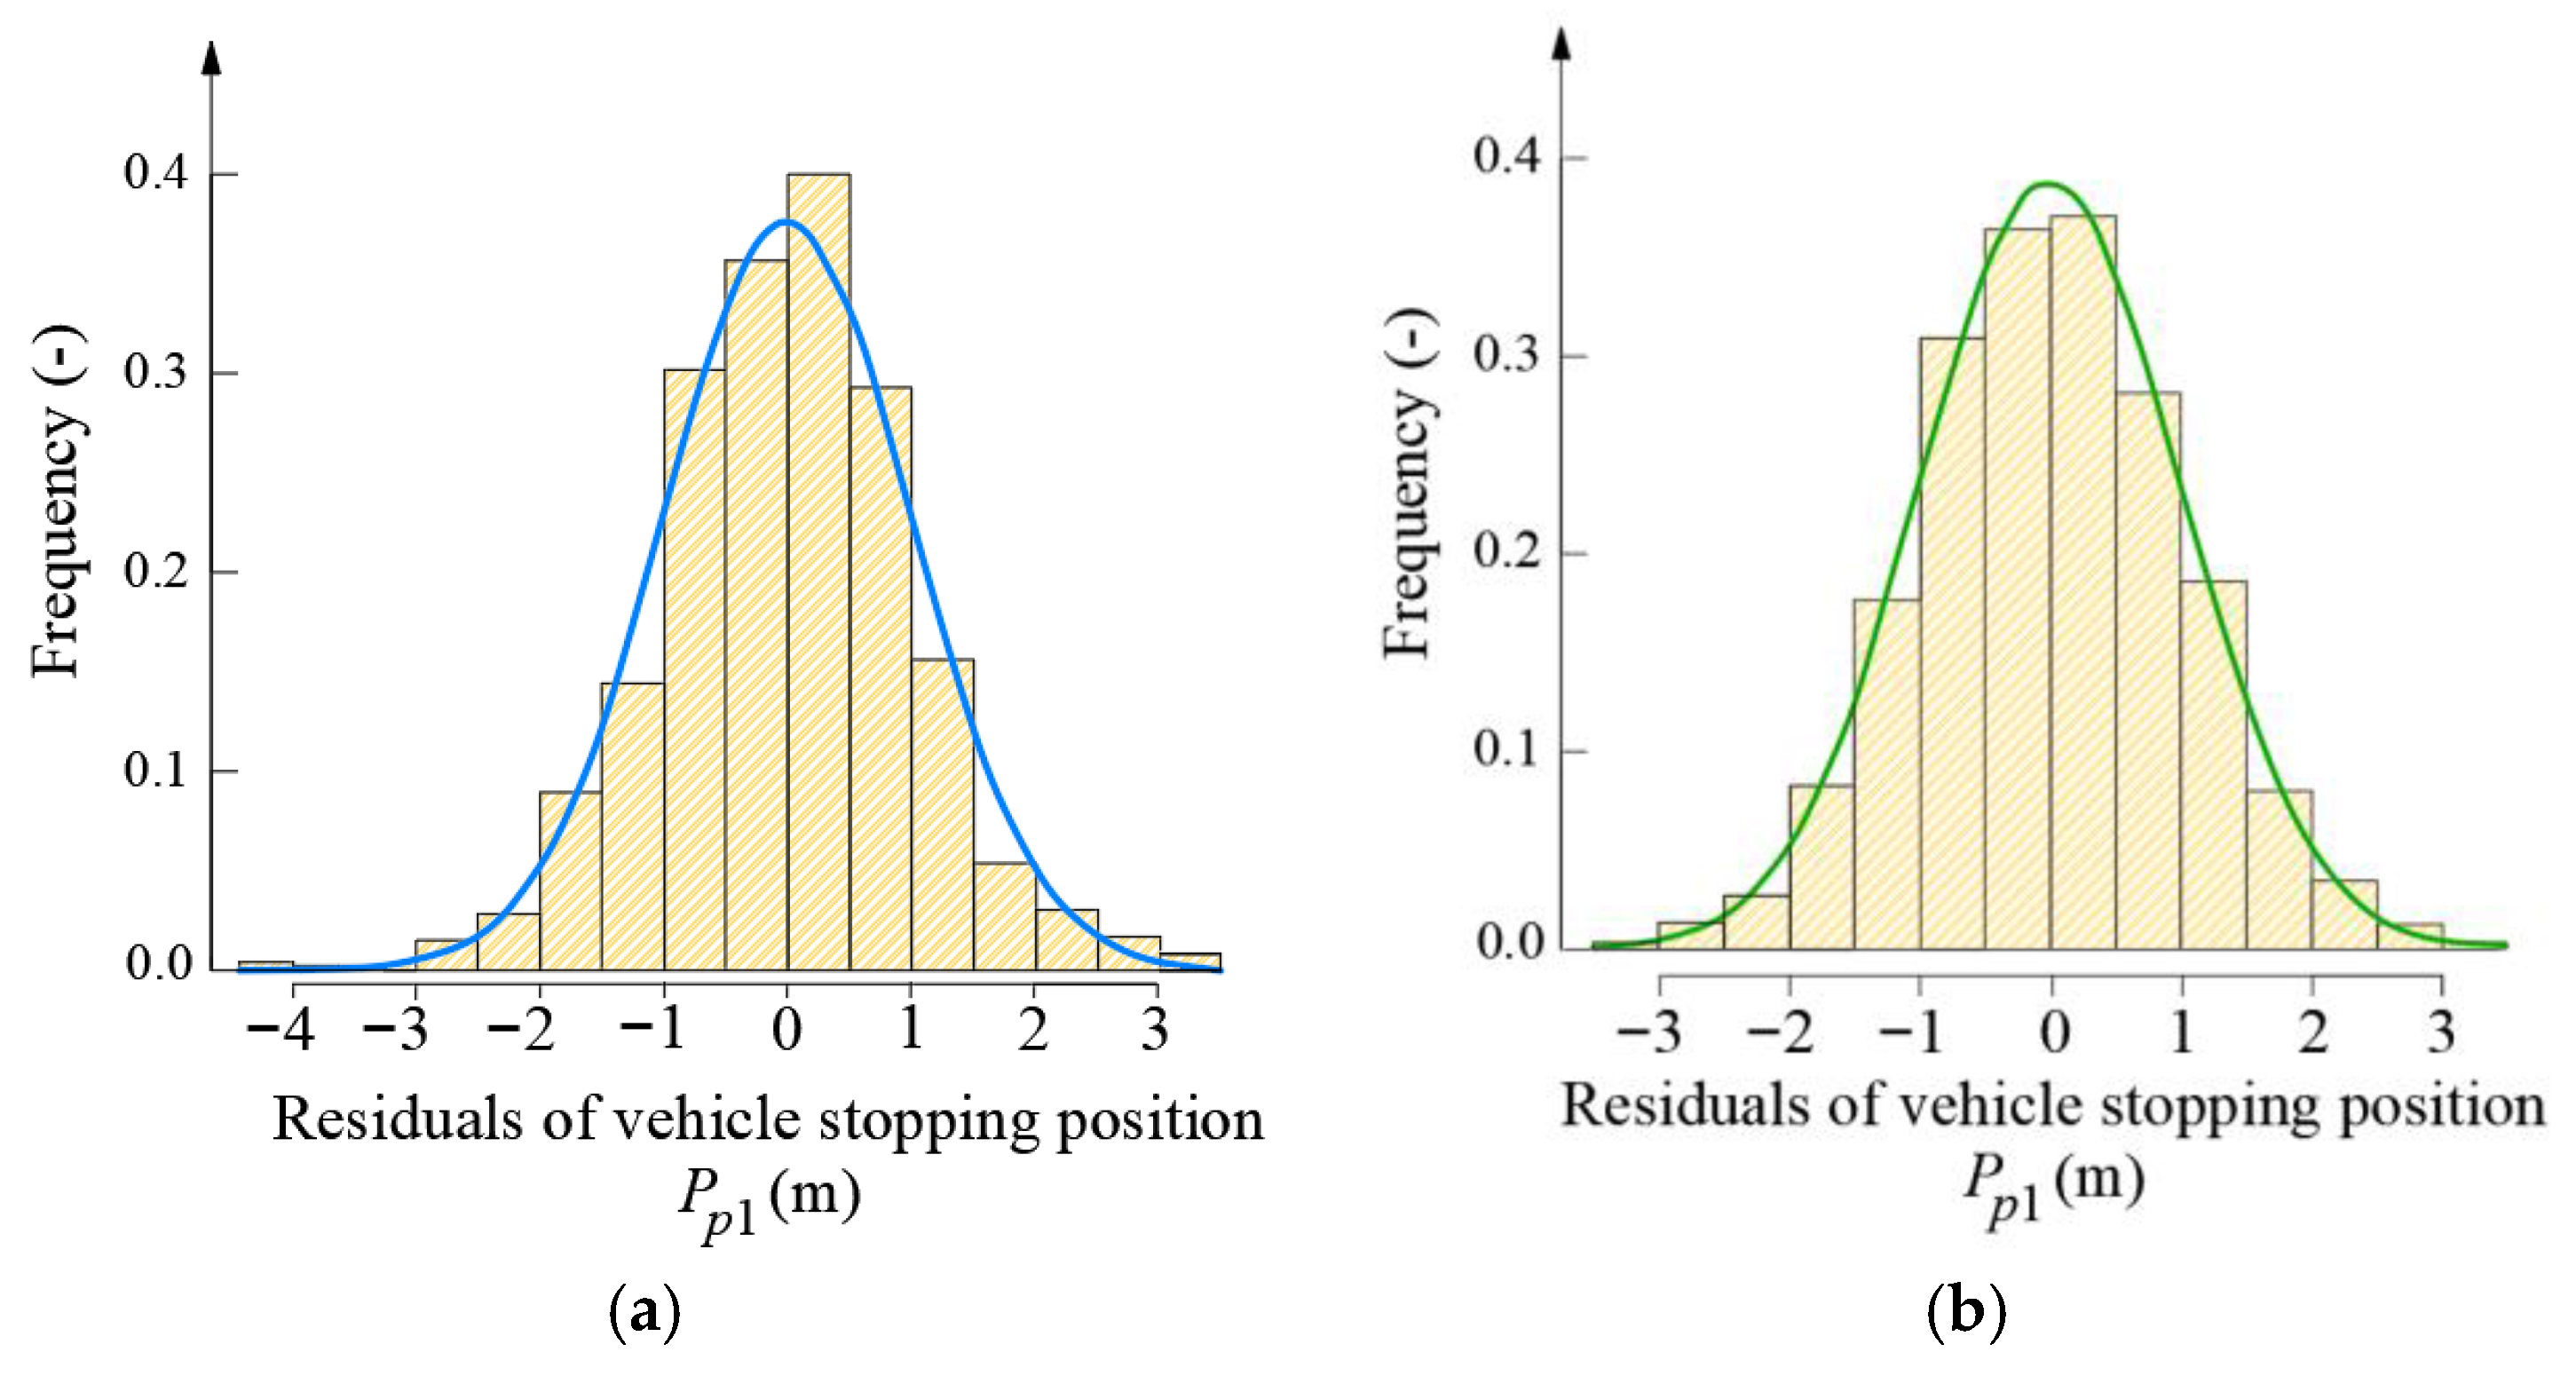
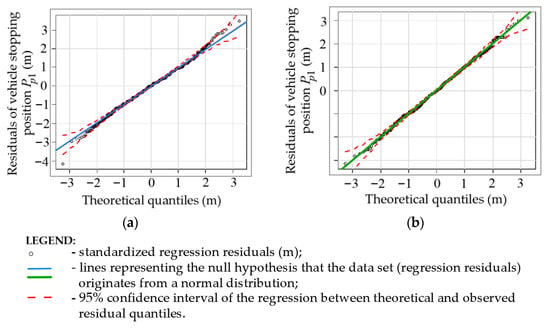
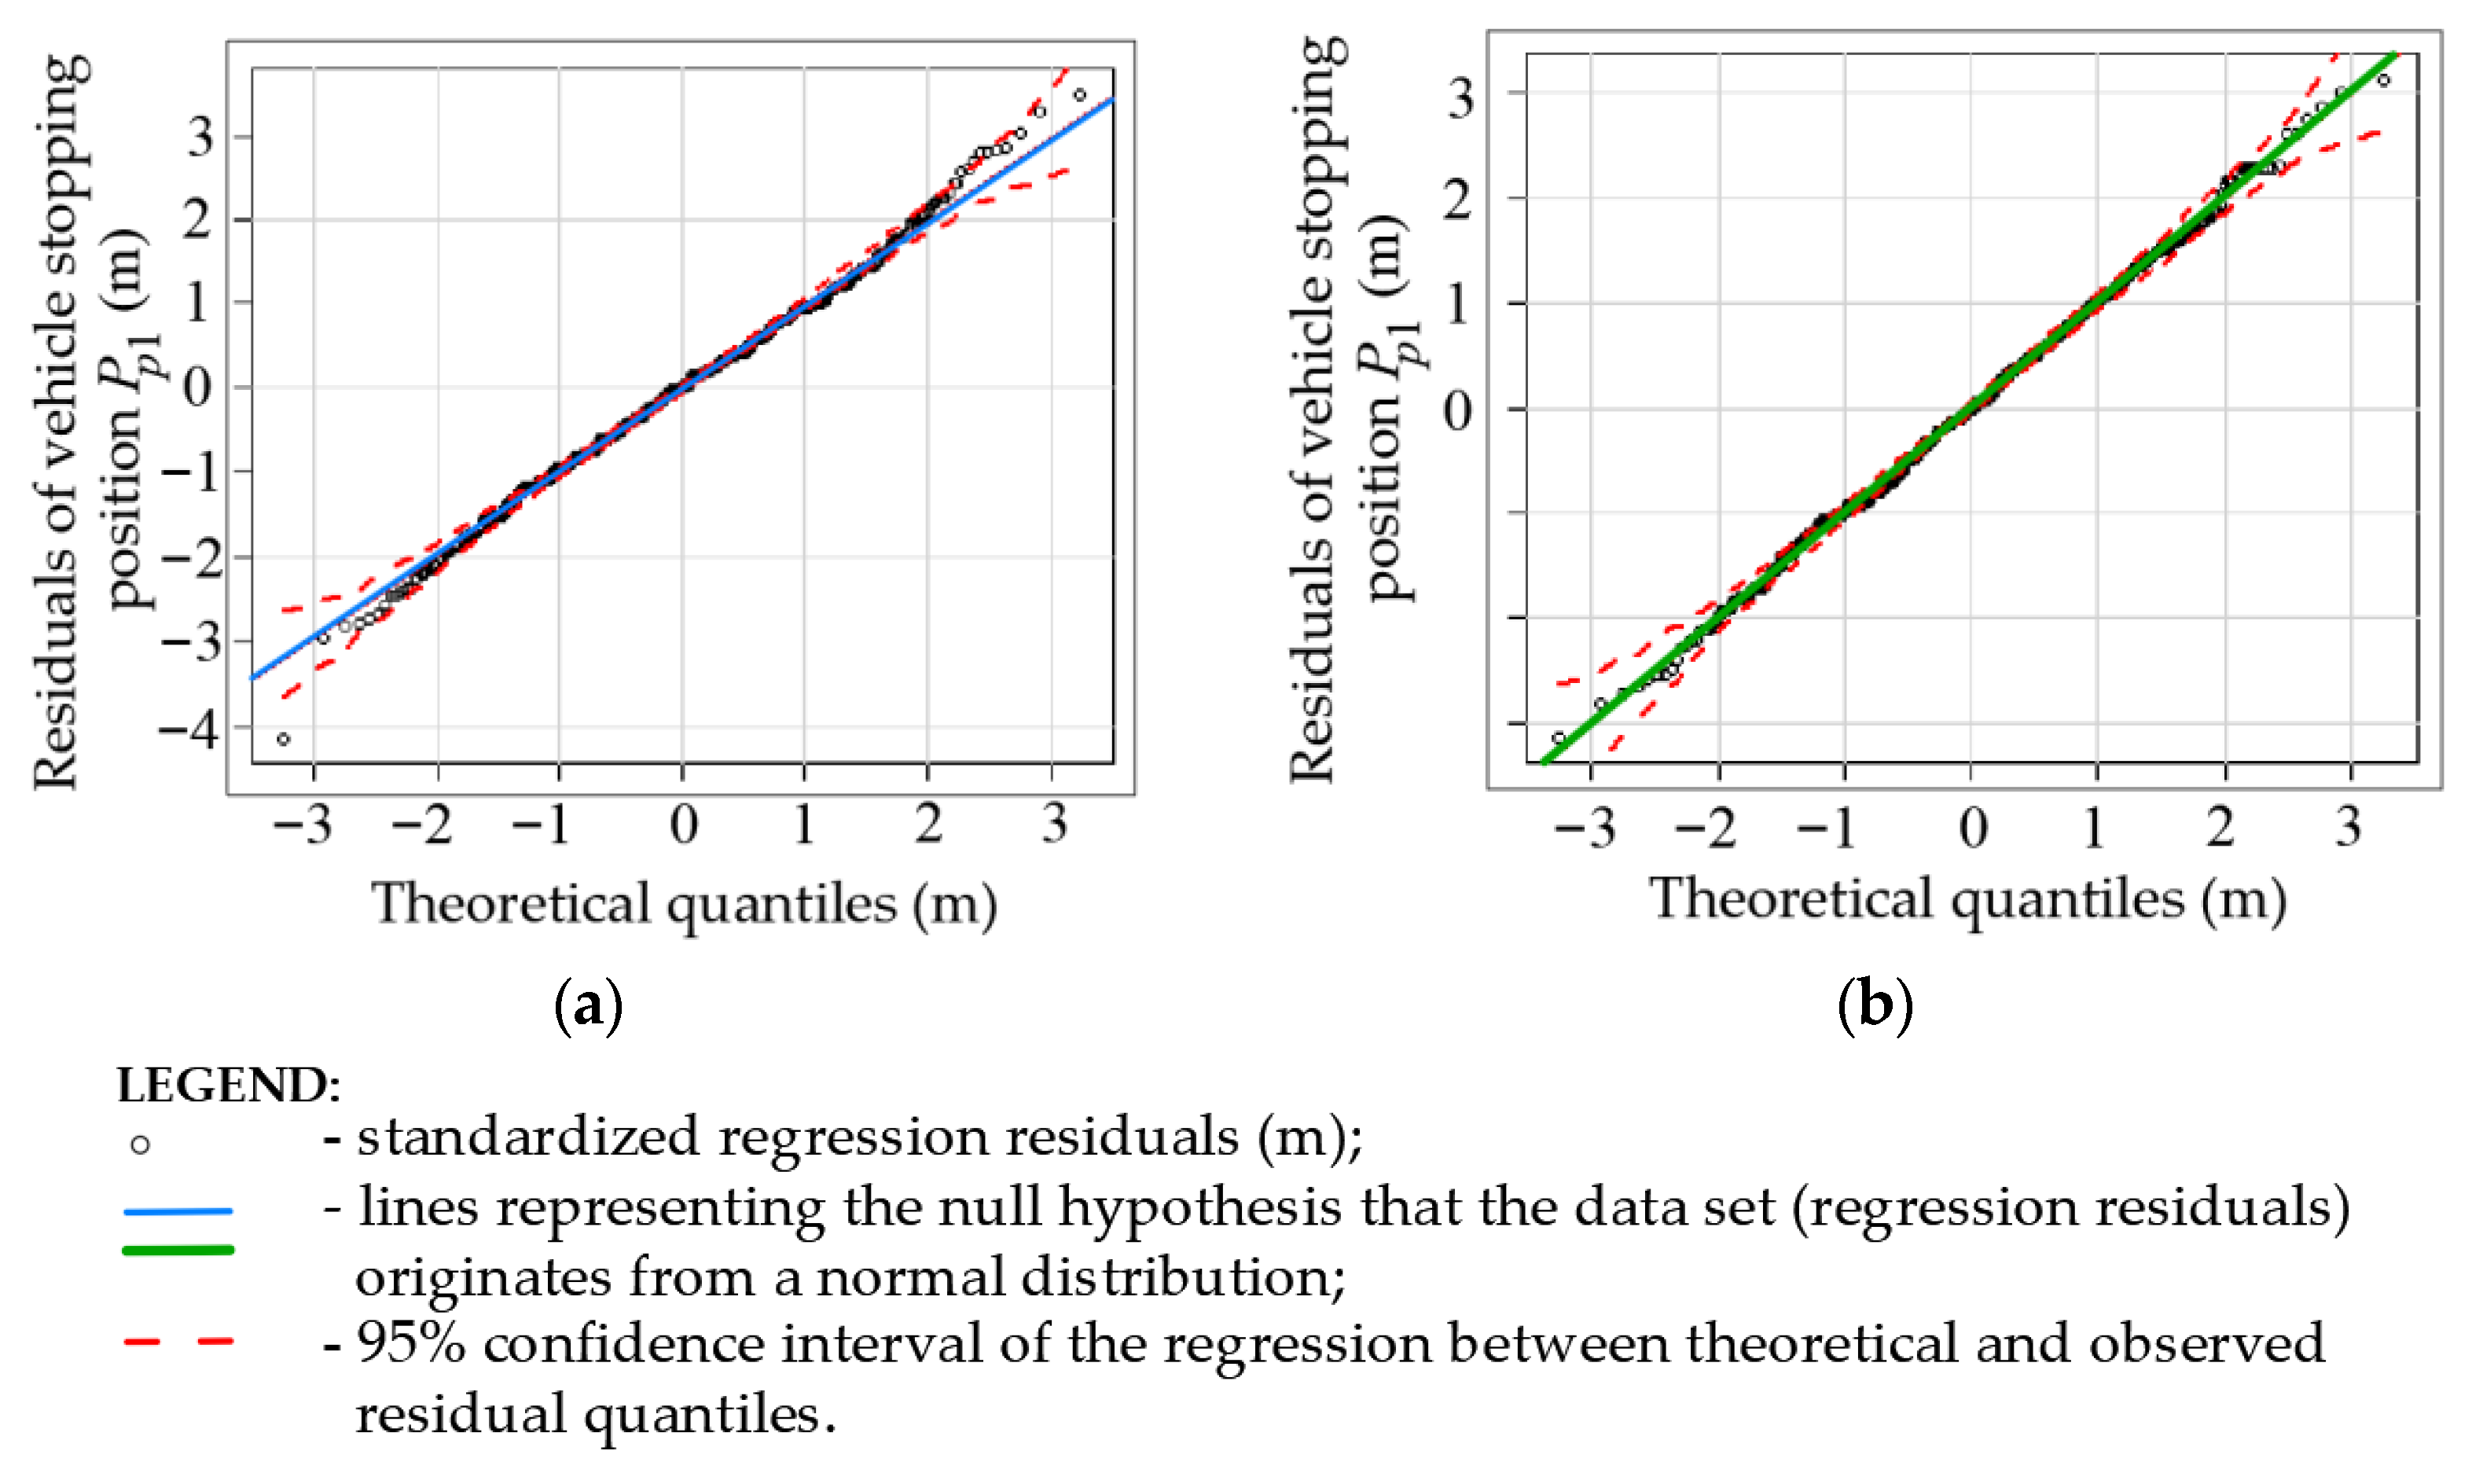
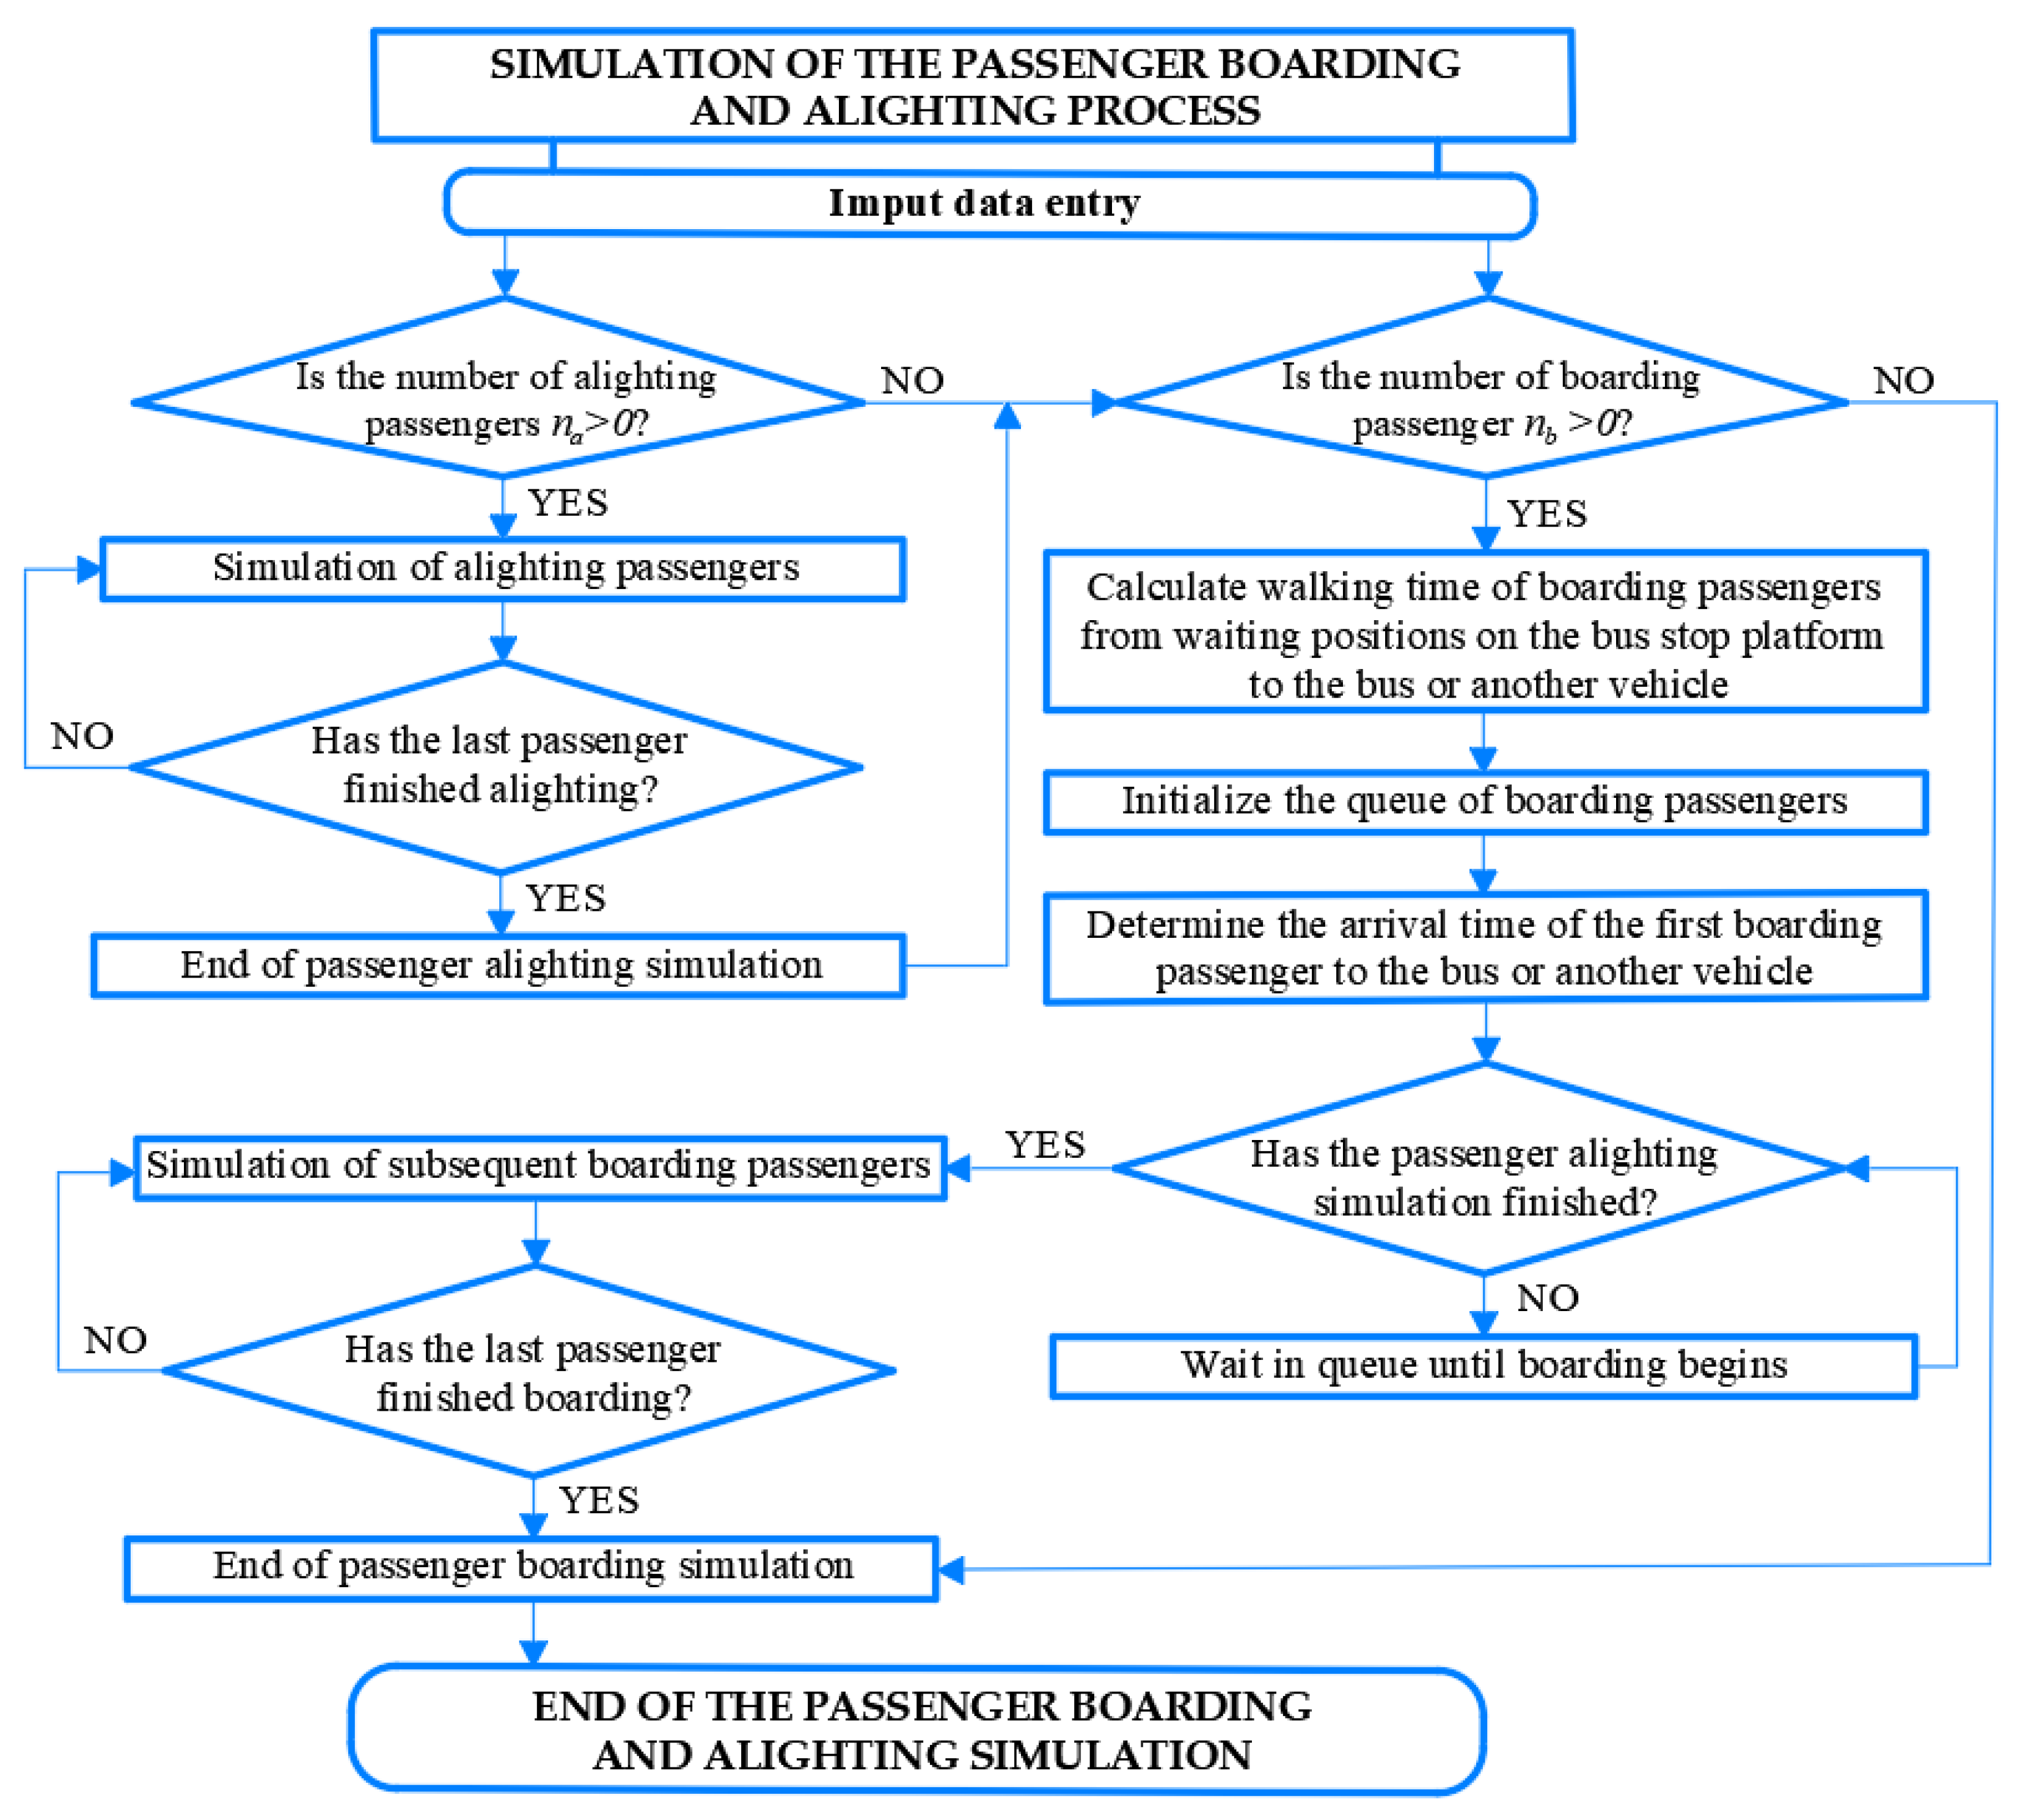
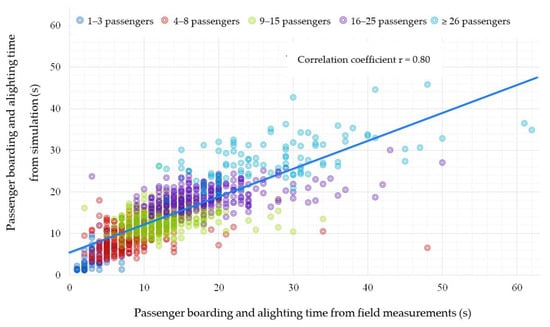
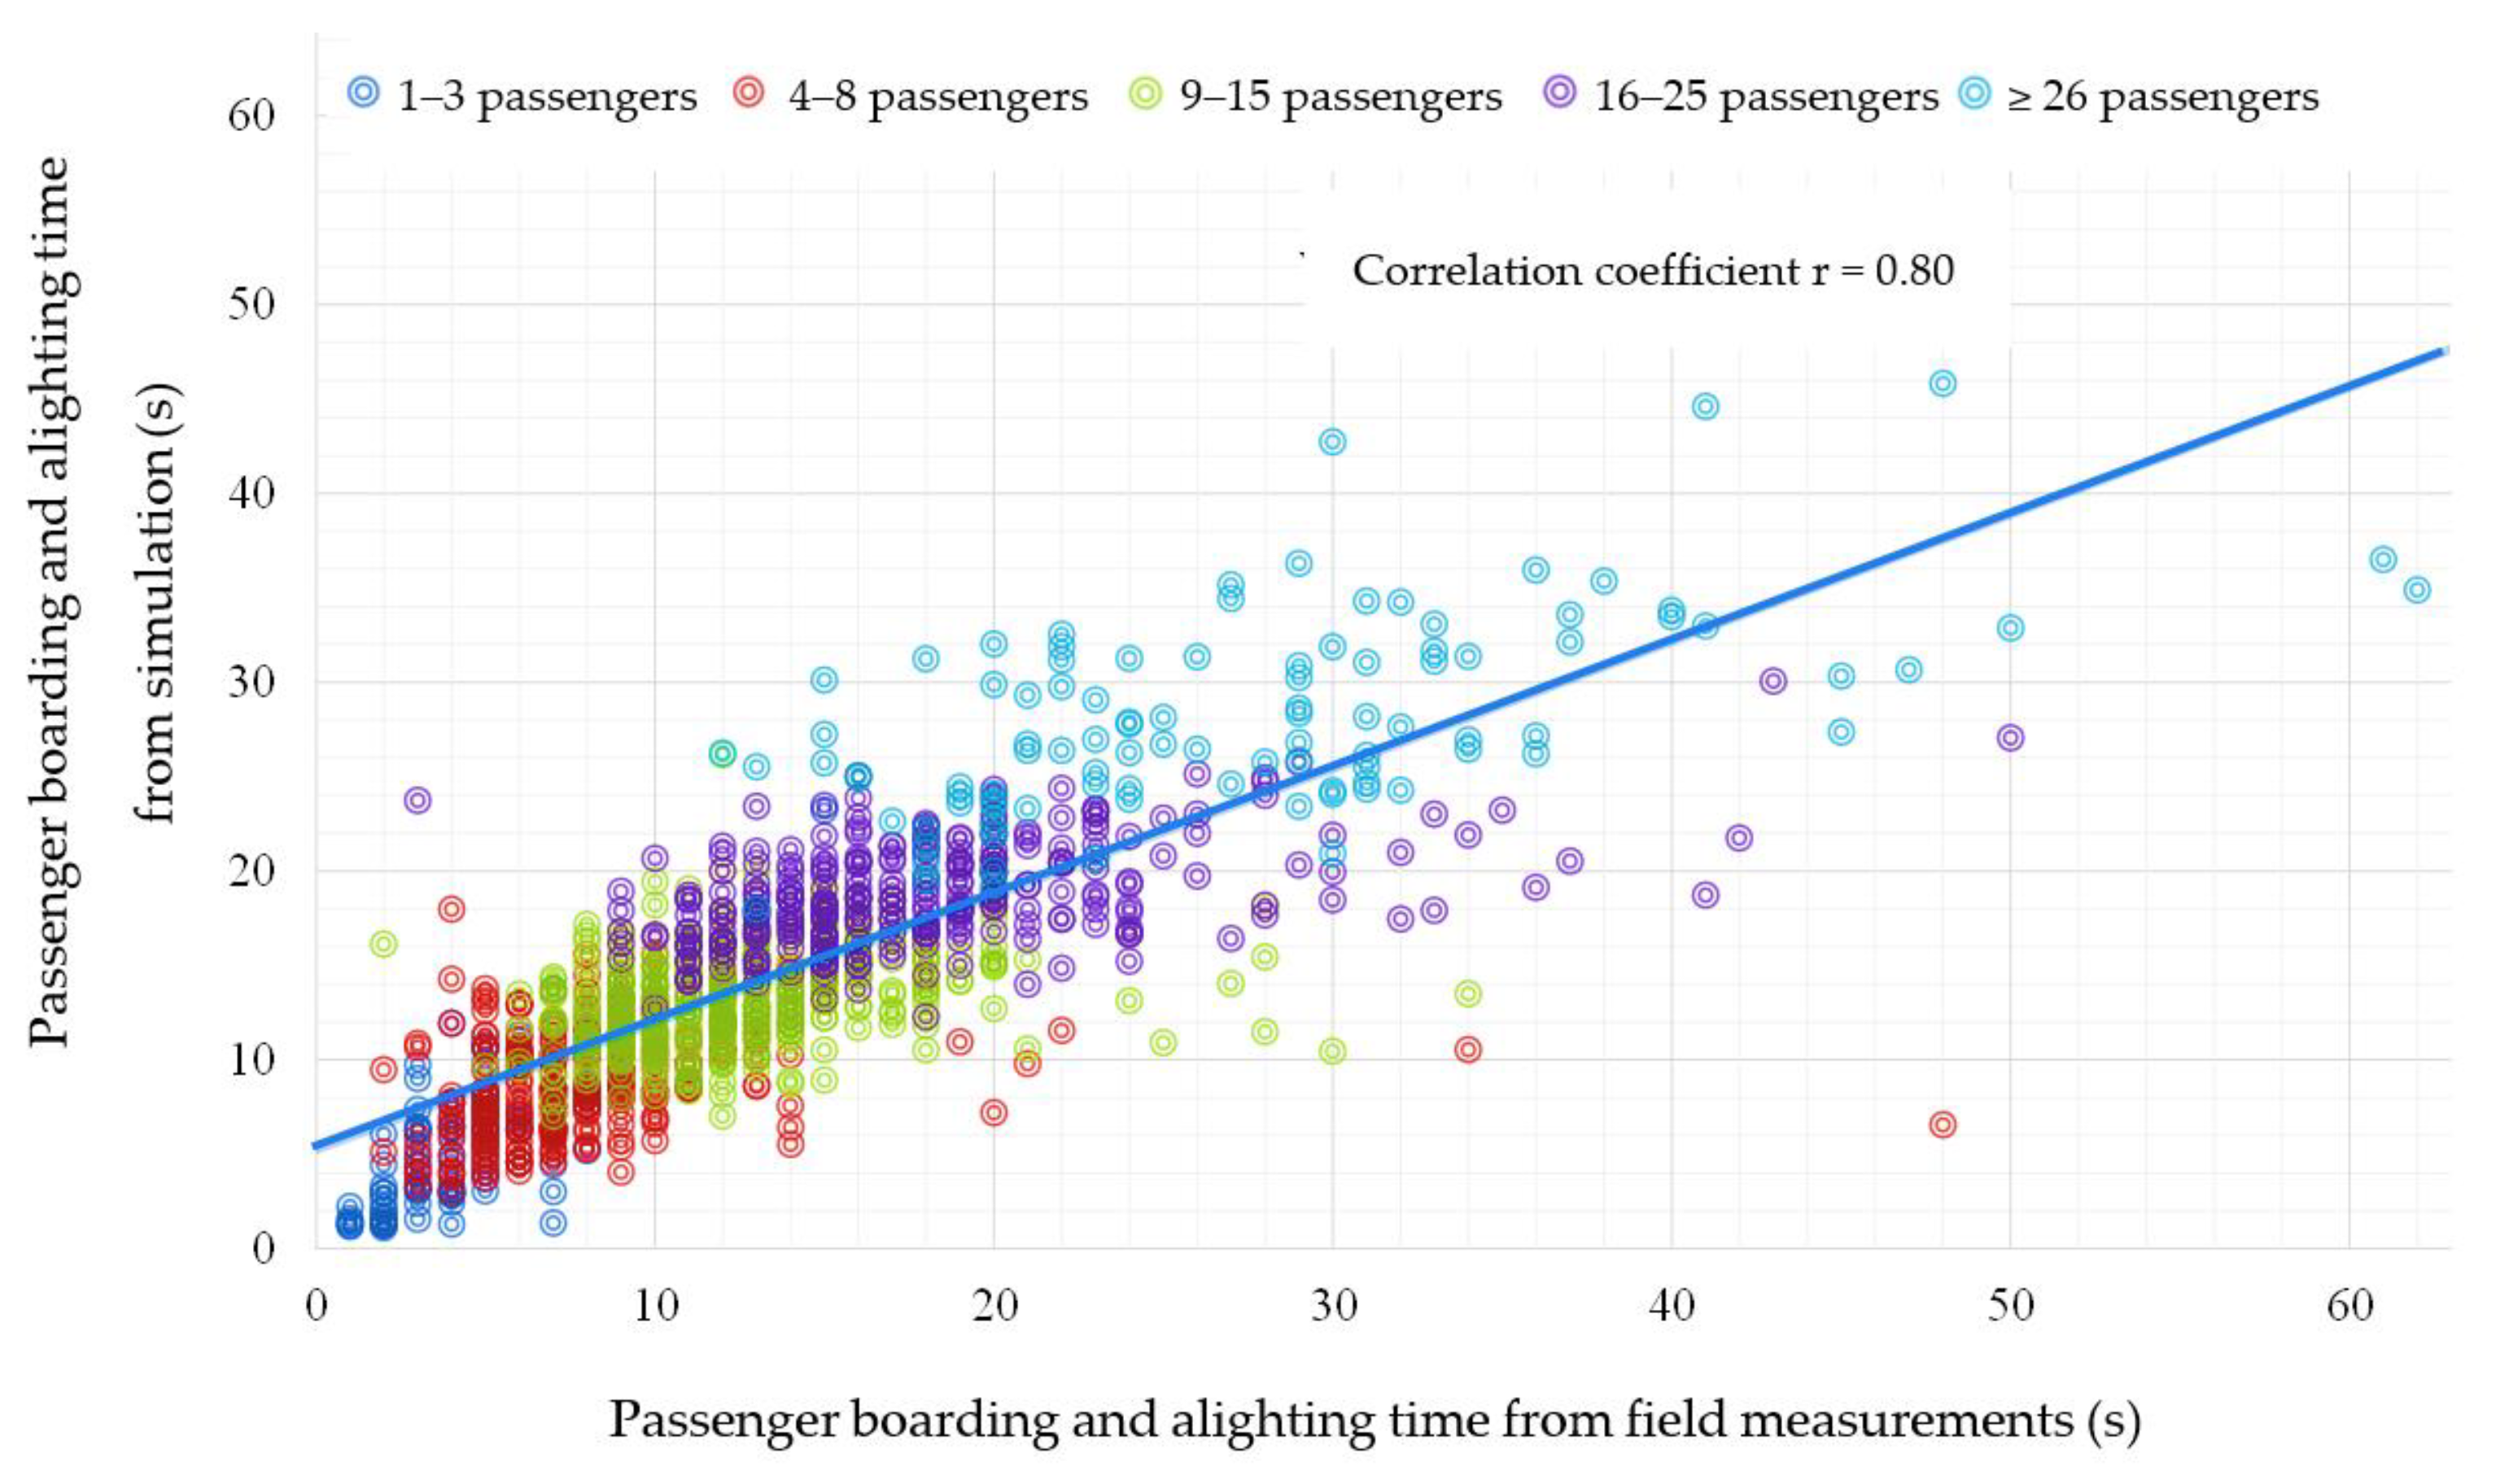
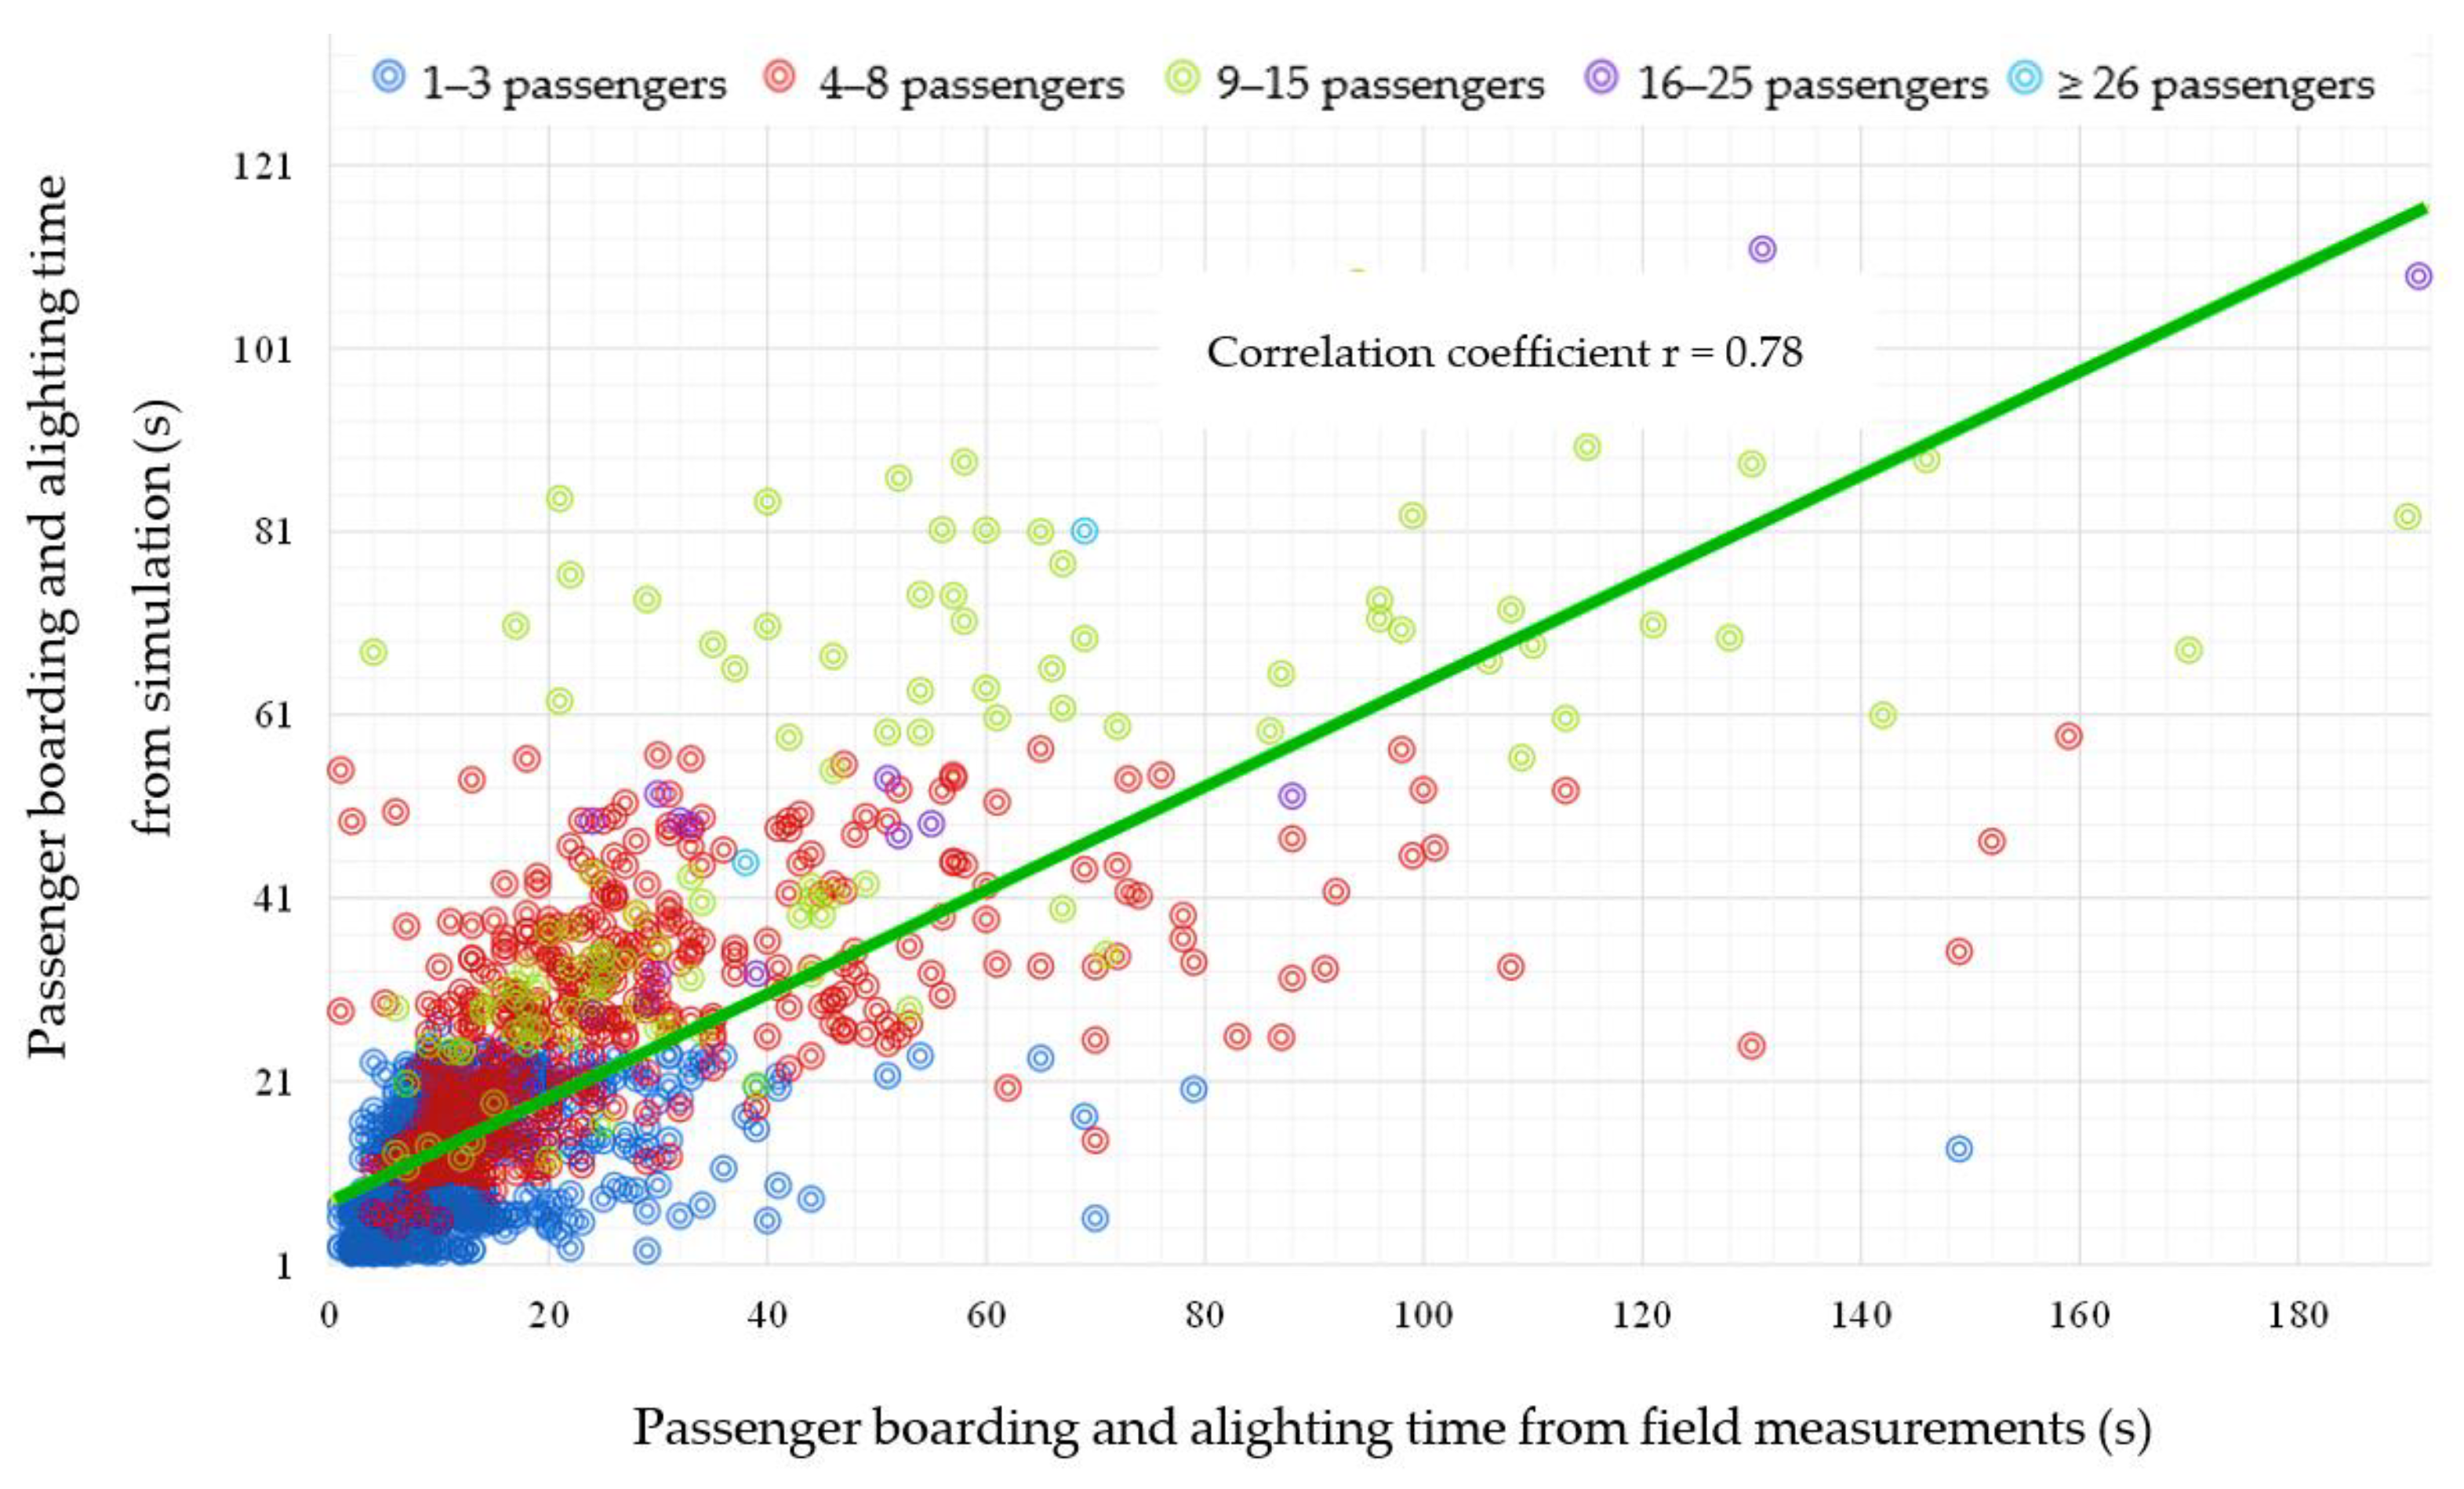

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2025 by the author. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.