


Abstract
As the market environment becomes increasingly complex, the demands for supply chain performance and security are continuously rising. Consequently, it is crucial to consider the role of trust factors within the system. This paper introduces a trust mechanism in the interaction between supply and demand within supply chain logistics and information flow. The supply chain system, characterized by varying degrees of trust, is modeled as multiple subsystems using the T-S fuzzy model. The challenge of mitigating the bullwhip effect, which refers to the amplification of demand variability within the supply chain, is reformulated as an consistency problem. A productivity and distributed consistency protocol switching controller based on fuzzy rules is designed, providing sufficient conditions for the entire system to achieve consistency. The proposed method effectively suppresses the bullwhip effect and allows certain nodes in the system to be temporarily in an abnormal state. Finally, the method’s effectiveness is validated through simulation examples.
1. Introduction
In the context of Industry 4.0, the traditional supply chain model is evolving into an intelligent supply chain model [1,2]. The data-driven intelligent manufacturing model relies on a robust and reliable supply chain, making trust evaluation of the supply chain critically important [3]. Essentially, the supply chain system (SCS) is a network control system that integrates information flow and logistics, comprising entities such as suppliers, manufacturers, distributors, and retailers [4]. These entities can independently sense the environment, make decisions, and interact with other entities, thus allowing the supply chain system to be modeled as a multi-agent system.
Trust is a crucial concept in multi-agent systems, forming the foundation for cooperative behavior and various forms of social actions [5]. When modeling the supply chain network as a multi-agent system, agents often need to collaborate with one or more other agents. By selecting partners based on the credibility of candidates, such cooperation not only enhances efficiency but also strengthens the security and stability of the supply chain [6]. Through mutual coordination and interdependence among multiple agents, the impact of uncertain demand caused by market volatility can be effectively mitigated [7,8].
In recent years, numerous studies have explored trust issues within the supply chain (see [9,10,11,12,13,14,15]). For instance, [12] proposed a method to address the evaluation and selection of long-term cooperative suppliers in the supply chain based on trust factors. Ref. [13] demonstrated that trust enhances the utility and flexibility of supply chains in managing daily fluctuations in supply and demand and addressing uncertain user needs. Ref. [14] elucidated the relationship between trust, relational capability, and supply chain performance. Ref. [15] used structural equation modeling to show that establishing a high-value supply chain requires managers to ensure optimal trust. However, existing models struggle to accurately describe the operational state of the supply chain system under varying levels of trust and to dynamically regulate the system according to trust values. Therefore, it is reasonable to construct a supply chain system model that incorporates a trust mechanism and to design a controller to regulate the system state based on trust information.
Inventory state control is a crucial aspect of supply chain management. The main goal is to minimize inventory costs while meeting user demand, and incorporating trust factors in the supply and demand chain can enhance efficiency and stability. In recent years, researchers have conducted numerous studies on inventory management and performance optimization of supply chain systems using multi-agent systems (see [16,17,18,19,20,21,22]). For instance, ref. [17] discussed the utilization of an integrated procurement-production-inventory model to enhance company performance and reduce costs. Ref. [18] explored how machine learning techniques can strengthen the sustainability of the supply chain and optimize logistics and inventory management. Ref. [22] considered the management of inventory under dynamic demand and stochastic time scales. In the field of supply chain inventory system management, few scholars have focused on the stability and robustness of the system. However, the stability and performance of the system are significantly impacted by continuous interference from uncertainty factors and unexpected events. Control theory provides a framework for achieving stability through systematic thinking, whether globally or locally. The supply chain system is dynamic, and its stability and response time are seriously affected by uncertainties. Therefore, integrating control theory with supply chain inventory management is effective and logical. It is reasonable to propose a dynamic multi-agent supply chain model based on a trust mechanism, combined with control theory.
To incorporate the concept of trust value into the supply chain system, this paper employs a fuzzy model to integrate trust value information with the supply chain model. The Takagi–Sugeno (T-S) fuzzy model is significant in the field of system modeling and control, offering unique advantages for handling complex, nonlinear systems (see [23,24,25]). Consequently, this paper constructs a productivity and distributed consensus protocol controller based on fuzzy rules derived from the T-S fuzzy model.
There are various methods for assessing supply chain performance, including (1) total supply chain cost, (2) service level, (3) average inventory, and (4) the bullwhip effect, among others. Among these performance assessment procedures, we focus on the bullwhip effect because it is a critical area of applied research in supply chain management [26]. Market demand can fluctuate due to factors such as customer satisfaction, product reliability, and the economic environment. The change in demand orders within the supply chain is often amplified as they move upstream, a phenomenon known as the bullwhip effect [27]. When managers design production plans based on inaccurate demand information, it can lead to excessive product inventory and increased inventory costs. The bullwhip effect can be measured in various ways, such as by comparing the variance between demand and orders, using different demand models, and considering cost factors [28]. The choice of measurement method should align with the research purpose and context. In this paper, we measure the bullwhip effect using the ratio of operating cost y to uncertain demand .
Remark 1.
Where denotes the norm. The equation suggests that when γ is smaller, indicating a lower operating cost to address uncertain demand, the attenuation performance of the bullwhip effect improves. By focusing on reducing the impact of uncertain demand, we can transform the problem of attenuating the bullwhip effect into a control problem, with the attenuation of uncertain demand serving as the control objective.
The main contributions of this paper are outlined as follows. First, the paper transforms the challenge of suppressing the bullwhip effect in supply chain management into a control problem. The primary objective of this control approach is to prevent uneven warehouse distribution, thereby reducing inventory costs. Given that control technology has demonstrated strong performance in mitigating the bullwhip effect caused by uncertain demand [29], this paper applies control technology to the supply chain system to achieve this suppression. Second, the paper introduces trust value information into the supply chain system using the T-S fuzzy model. A productivity and distributed consensus protocol switching controller, which relies on fuzzy rules, is designed. Incorporating trust values allows the supply chain system to better reflect practical and complex supply scenarios, thereby enhancing system stability. Finally, the paper provides sufficient conditions for ensuring consistency. In situations where the system experiences a failure at a particular node due to a major emergency, the average dwell time method is utilized to maintain system stability.
2. Multi-Agent Supply Chain Model
Suppose the weighted graph of N subchains is , where each node is a subchain, and the facilities in each subchain can be considered as children of the node. is the set of nodes containing the vertices of all nodes, . is the set of edges in the graph. When nodes belong to the same edge and can communicate with each other, j is said to be a neighboring node of i. Denote the set of neighboring nodes of node i by . When a node does not have any neighboring nodes, it is called an isolated node. The weighted adjacency matrix between individual nodes is denoted as , where if and only if i and j are neighboring nodes. The Laplace matrix of the graph G is defined as
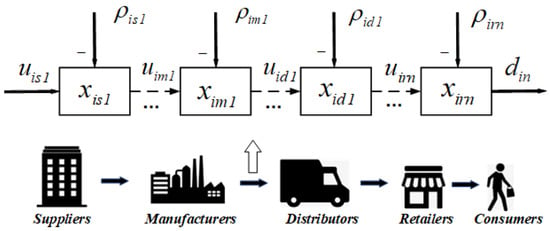
Based on the discussion above, we consider a multi-agent supply chain system. This system comprises N sub-chains, each treated as an intelligent agent and represented as a node within a graph. Each sub-chain contains n facilities. Figure 1 illustrates the i-th sub-chain, where represents the inventory status of the first supplier facility in the i-th sub-chain.
where represents the inventory status of the ith subchain at time k, denotes the productivity at time k, indicates the market demand at time k, and is the loss rate in the warehousing process. The production and supply process for each subchain commences with the supplier providing the means of production, progresses through a sequence of processing facilities, and concludes with the customer purchasing the finished product. Here, represents not only the productivity of the current facility but also the demand of the preceding facility. Market demand directly influences only the final facility, yet it propagates through the supply chain, impacting all nodes. From a control perspective, x can be viewed as the inventory state at time k, u as the control input, and d as the external perturbation.
Figure 1.
Subchain i production process with n facilities.
To model the supply chain system, we must establish the following assumptions.
Assumption 1.
Goods in the warehouse will have a certain amount of wear and tear with storage time, and different goods in different warehouses have different rates of wear and tear.
Assumption 2.
The user’s demand is divided into a known regular demand , and an unknown time-varying demand , so that the demand is represented as
In Assumptions 1 and 2, the ith subchain is modeled as
where
In a supply chain system with N sub-chains, it is necessary to compare inventory levels between neighboring nodes to adjust productivity and achieve system consensus. To ensure the stability of this supply chain system and reach consensus, two controllers must be designed to meet the control objectives: the production controller, which adjusts the production rate based on the local conditions of each sub-chain, and the consensus agreement controller, which modifies the production rate through communication with neighboring nodes, facilitating consensus among all agents.
Remark 2.
It is important to note that communication between agents is subject to delays. Specifically, the production communication delay between two facilities within the same subchain differs from the consensus communication delay between two subchains. The following section will provide a detailed description of the choice of delay.
Thus, the controller of the subchain is
where is the production rate gain, is the consensus gain, and . In addition, , where , is a positive scalar constant and is an upper bound on the time lag, while denotes the inventory control objective of the ith subchain.
Substituting (5) into (4) yields the kinetic equation for the ith subchain as
where , , is the th element in the Laplacian matrix L.
A multi-agent-based supply chain system model can be obtained by aggregating the sub-chains.
where , , and L is the Laplace matrix of the graph.
The average inventory status of the system is , and the error between the inventory state of each agent and the average inventory state is . According to Equation (8), we can obtain the error equation for the ith subchain as
where . The complete supply chain error system is as follows:
where , , and is the output of the system.
Remark 3.
In a multi-agent system, the consistency problem can be redefined as a stabilization problem of an error system, where the error is the deviation between the state value of each agent and the target value. When the error is zero, it indicates that the system has reached consistency and achieved the control objective
3. T-S Fuzzy Model
Previous studies indicate that the trust value between two nodes influences the degree of information sharing between them. A higher degree of sharing correlates with increased frequency of information interaction [6,30,31]. For instance, ref. [30] categorizes the degree of information sharing into four levels based on trust value and provides a detailed description of the interaction status between nodes at these levels. Consequently, the trust value informs us about the strength of information interaction between nodes and the duration of any communication lag. Additionally, as trust value increases, the frequency of interaction between nodes rises, leading to reduced inventory loss from backlogs; thus, a higher trust value corresponds to a lower inventory loss rate.
For simplicity, consider the supply chain system scenario consisting of two sub-chains, with being the premise variable and being the fuzzy set. In this paper, is each sub-chain’s global trust value level.
Nine scenarios are considered based on the high and low global trust levels of the two sub-chains, as shown in Table 1. Here, the superscript in denotes the number of sub-chains, while the subscript represents the three trust scenarios: high, medium, and low, respectively. This framework can fully approximate the dynamic relationships among the nine scenarios in the actual product and supply process. Moreover, it enables the construction of T-S fuzzy set divisions and fuzzy rules for the nine subsystems.
Table 1.
Fuzzy rules under different trust.
According to the subsystem division rule, let denote complete trust, and denote complete distrust, while is the fuzzy range that lies between the two cases.
A fuzzy set is established based on the above, and the affiliation function of is , whose expression is shown in (11)–(13).
The system dynamics equations for the production process of the supply chain under different rules are as follows.
Rule 1: IF is , and is , then
where , ,
Rule 4: IF is , and is , then
where , ,
Rule 9: IF is , and is , then
where , ,
In the above equations, , , and denote the upper and lower bounds of the storage loss rate, interaction strength, and interaction delay, respectively. The variable h represents the scaling gain of the controller, which varies with the strength of the interaction. Consider Rule 1 as an example. In this case, the trust value of both sub-chains is at its highest level when the degree of information sharing among the nodes reaches a peak. The interaction strength between nodes is at its maximum, and the information transfer delays are at their minimum. Ideally, this can be regarded as a zero-inventory supply state that realizes just-in-time production and sales. Consequently, the inventory loss rate due to backlog is significantly reduced. Simultaneously, the scaling gain h is maximized, meaning a greater weight is given to the consistency protocol controller. The equations corresponding to the remaining rules are analogous to the above and are not enumerated here.
Using the T-S fuzzy model to model the supply chain system can obtain the global system as
where , , is value of the affiliation function of in .
4. Model Stability Analysis
This section provides the solvability conditions for the problem in a multi-agent-based supply chain system. The controller parameters that meet the requirements are obtained by solving linear matrix inequality (LMI) equations. For the system to achieve performance , the following conditions must be satisfied:
The error system (18) is exponentially stable at (i.e., there exist scalars a and b such that ). The norm of the transfer function from the disturbance input to the system output is less than , that is, under the condition , , where is the decay level of the bullwhip effect.
To complete the proof, it is also necessary to introduce the following lemma.
Lemma 1
([32]). (Moon’s inequality) For any vectors of appropriate dimensions and matrices If , the following inequality holds
For the system (10), choose the Lyapunov function as
where
where and are symmetric positive definite matrices of appropriate dimensions.
Based on the above conditions, we can derive the following lemma:
Theorem 1.
If Assumptions 1 and 2 hold, for a given scalar the system (18) has performance γ. If there exist symmetric positive definite matrices symmetric semipositive definite matrices , then
and
where
Proof of Theorem 1.
Obviously, satisfies
Consequently,
Consider that when , for the Lyapunov function (15) along the trajectory of the system (10), for the forward difference, we have
where
It follows from (23)
Combining this with Lemma 1 yields
where are symmetric matrices of appropriate dimension and
The same reasoning can be used to obtain
where are symmetric matrices of appropriate dimension and
Consequently,
where
Continuing the calculations, we have
where
An equation of the same kind obtains
where .
Using the Schur complement lemma, it can be shown that LMI (20) is equivalent to . The system (18) is stable by Liapunov’s stability theory.
Next, under zero initial conditions, consider the performance metrics
Then, for any , it follows from the properties of the Lyapunov generalized function and the zero initial condition that
where
By Schur complement lemma, (20) is equivalent to and thus , i.e.,
Thus, the system (18) has performance . □
In the operation of a supply chain system, major accidents can lead to the failure of nodes, resulting in what we term “isolated nodes.” When the supply chain cannot meet the supply demand, the system proactively replaces and upgrades nodes to ensure overall security and efficiency. However, this process may temporarily result in isolated nodes. We define these failed nodes as the isolated nodes of the system, denoted by , where = 0 indicates that there are no isolated nodes, while = 1 signifies that the first node is isolated. For simplicity, we assume that only one node fails at any given time, and the failed node can be restored to normal operation after adjusting and replacing the supply facility. For systems with isolated nodes, there are
For the system (32), choose the Lyapunov function as
where
, and is a symmetric positive definite matrix of appropriate dimension.
Based on the above conditions, we can derive the following lemma
Theorem 2.
If Assumptions 1 and 2 hold, for a given scalar , the system (18) has performance γ. If there exist symmetric positive definite matrices symmetric semipositive definite matrices , then
and
where
The proof of Theorem 2 is similar to that of Theorem 1 and is omitted here for space reasons.
Theorems 1 and 2 provide the consensus conditions for supply chain systems under uncertain demand. The gains of the controller can be determined by employing methods similar to those presented in [33,34].
When a node in the supply chain fails, the system’s stability is compromised, rendering it non-stabilizable. Additionally, the disruption and restoration of nodes result in changes to the network’s topology, which subsequently alters the corresponding Laplacian matrix. To address both unforeseen events and the impacts of structural upgrades in the supply chain, we demonstrate that the system can remain stabilizable under certain conditions. Specifically, as long as a reasonable average dwell time is designed, and the ratio of the operating time of the non-stabilizable subsystems to that of the stabilizable subsystems is below a certain threshold, the switching system remains stabilizable.
Let denote the number of switches in time and for any . If there exist and , such that the following conditions hold, then is the mean residence time, and is the jitter-bound.
For simplicity and without loss of generality, we choose , which divides the time interval into two categories, with and without isolated nodes. Where , the absence of isolated nodes, is stabilizable, and , the presence of isolated nodes, is not stabilizable. Define as the number of times a stabilizable system switches to a system with an isolated node in ; denote by the total time a subsystem with an isolated node is running in .
Theorem 3.
Proof of Theorem 3.
For the switching system (37), the Lyapunov function is (19) when and is (33) when . Based on the above conditions, it follows that
From Lemma 1 and Theorem 2, it is known that
The error switching system (32) is exponentially stable because .
It follows from Lemma 1 that
where . The same reasoning leads to
It follows from (42) that
Under zero initial conditions, from (43), it follows that
Thus, supply chain systems containing isolated nodes, provided they satisfy the conditions outlined in Theorem 3, are exponentially stable and achieve an performance level of . □
Theorems 1–3 establish the conditions for the switching topology and consistency of a T-S fuzzy supply chain system based on a trust mechanism under uncertain demand. The design steps for the controller are as follows:
- Step 2: Determine the parameters of the supply chain system and the scaling gain of the consistency controller based on the fuzzy rules. This results in the supply chain error system model incorporating trust information, represented by Equation (18);
5. Numerical Example
In this section, the effectiveness of the proposed method will be verified based on simulation examples.
As coal progresses through various stages from raw to finished product, each storage phase is influenced by factors such as natural weathering, rain, and snow erosion, leading to varying storage loss rates. Considering the operational data of a coal enterprise [35], the model parameters are set as follows according to the actual situation and the historical data of the enterprise: the inventory loss rate is . The upper bounds of the interaction delay are given as and . The initial stock values for the three subchains are: tons, tons, and tons. The control targets for inventory are . The control objective is to ensure uninterrupted logistics and to manage inventory levels such that higher loss rates result in lower steady-state inventory. This approach aims to effectively reduce the economic losses associated with inventory loss rates. The parameters , , and are used in the model.
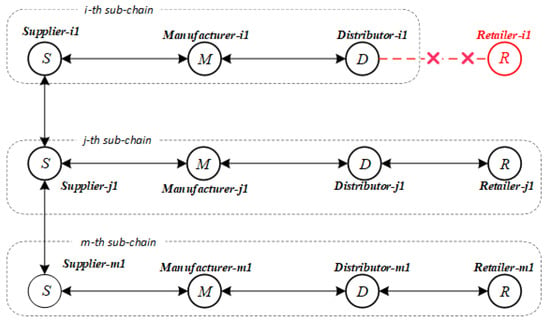
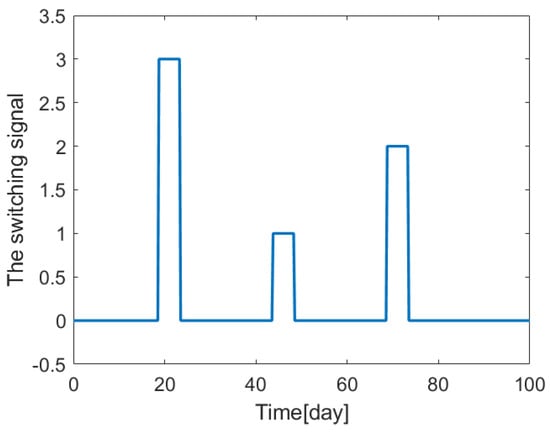
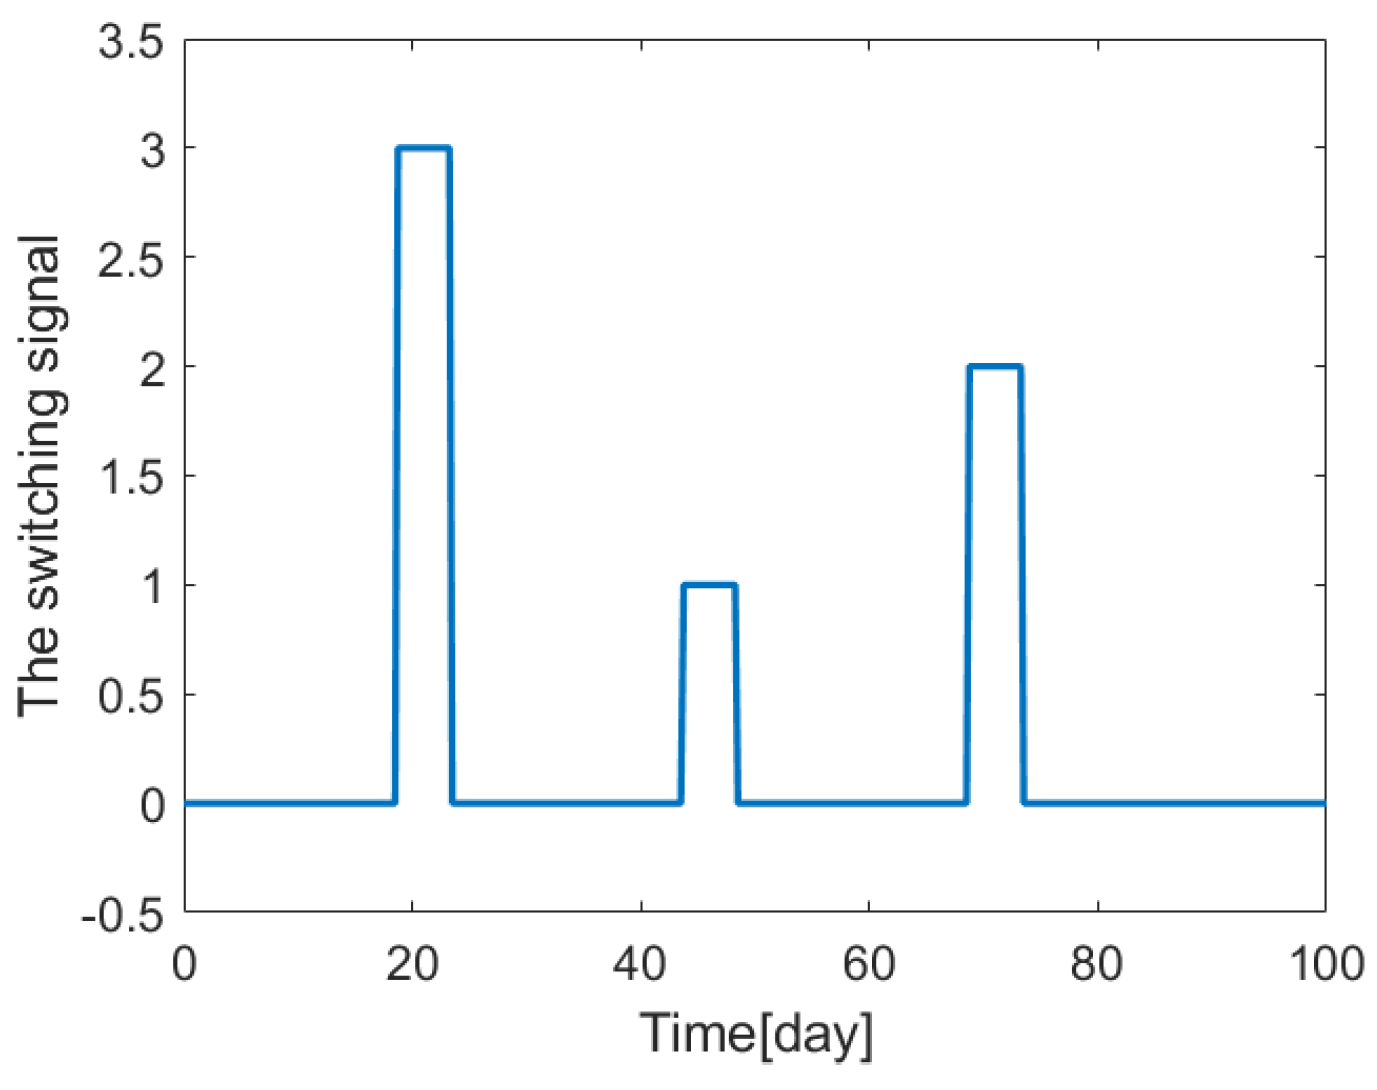
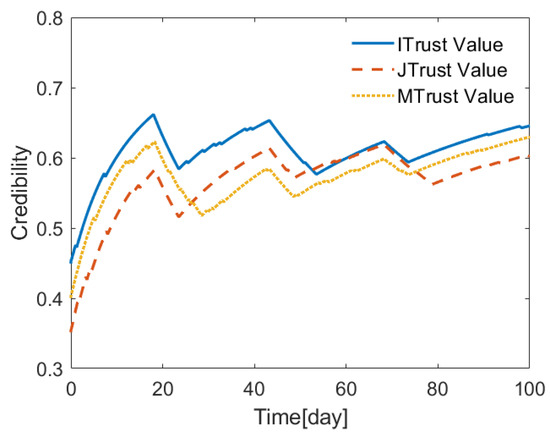
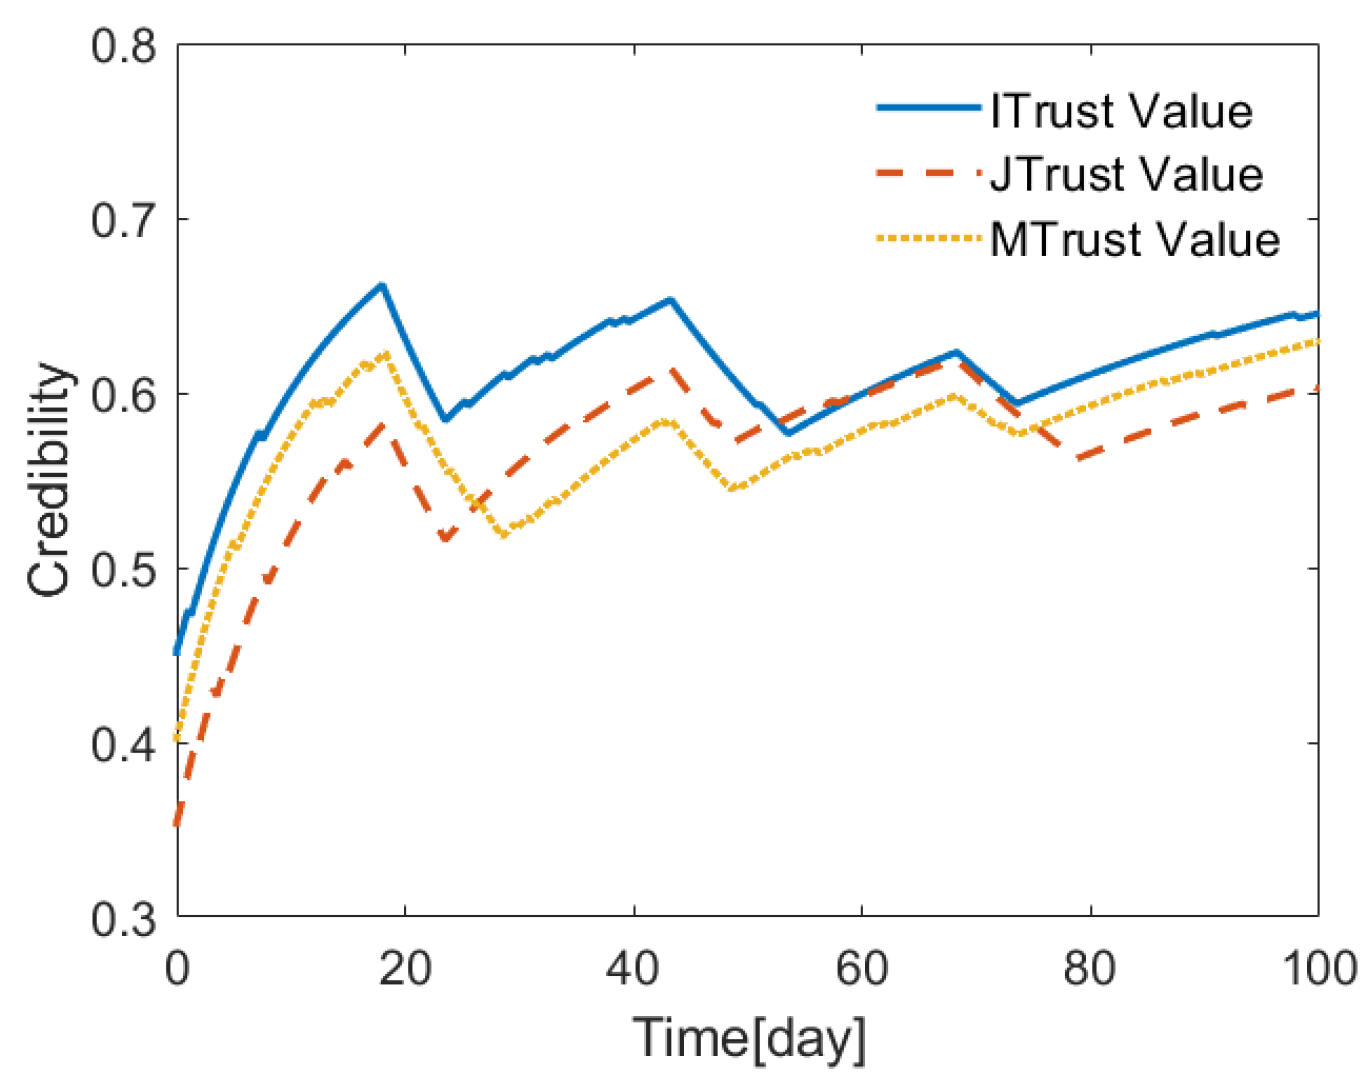
The system’s topology is forced to change when a significant accidental event occurs, causing breaks in the supply chain nodes and resulting in isolated nodes. The switching of the system topology is illustrated in Figure 2. During normal operations, the trust value between subchains increases with the number of successful transactions. However, the emergence of isolated nodes impacts the trustworthiness of each subchain to varying extents. The switching signals generated by the system due to isolated nodes are depicted in Figure 3, where the y-axis coordinates 1, 2, and 3 correspond to the presence of isolated nodes in subchains i, j, and m, respectively, and the corresponding changes in the trustworthiness of the subchains are shown in Figure 4. The controller gains are shown below.
Figure 2.
Topology switching (Red indicates isolated nodes).
Figure 3.
Switching signals.
Figure 4.
Trust change.
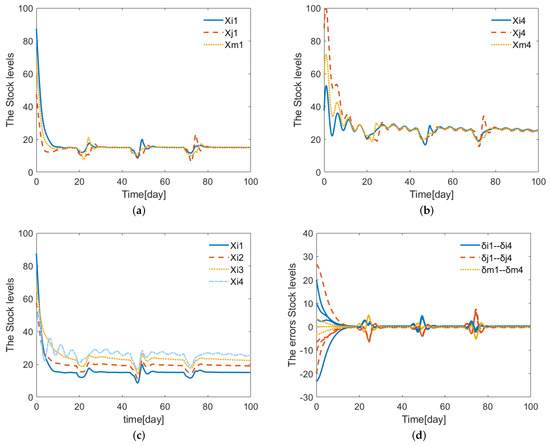
Based on the conditions described above, the changes in the inventory status of each node in the supply chain can be observed in Figure 5. In this figure, parts (a) and (b) represent the inventory changes at the head and tail nodes of the supply chain, which are most affected by perturbations. Part (c) illustrates the inventory changes of the ith sub-chain. Finally, part (d) displays the inventory error variation curves for all sub-chains.
Figure 5.
Inventory changes: (a) inventory changes at the supplier nodes of subchains i, j, m; (b) inventory changes at the retailer nodes of subchains i, j, m; (c) inventory changes at the four nodes of subchain i; and (d) changes in consistency error among all nodes.
From Figure 5, it is evident that the inventory levels of all facilities within the supply chain system converge to a uniform level. This prevents scenarios of stockouts in some regions and excess inventory in others due to uneven distribution, thereby enhancing the overall efficiency of the supply chain. At steady state, the inventory levels at each node in the sub-chain meet the desired inventory control objectives, contributing to improved economic efficiency. Additionally, the system demonstrates the ability to swiftly return to normal operation following disruptions, such as node updates or replacements, minimizing the impact and improving system stability. Therefore, it can be concluded that the supply chain model proposed in this paper effectively mitigates the bullwhip effect caused by uncertain demand. By ensuring system stability, it enhances supply chain performance, reduces economic losses, and minimizes the adverse effects of uncertainties.
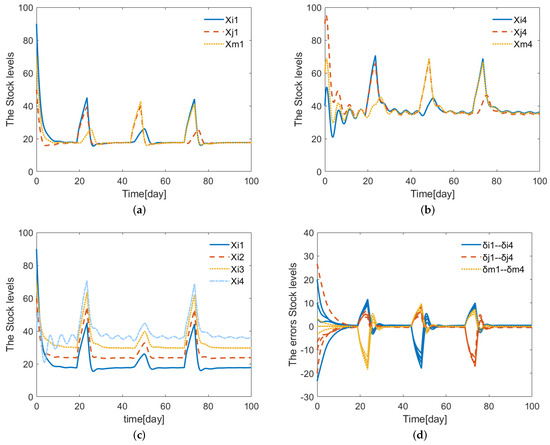
To verify the superiority of the proposed model, we compared the method presented in this paper with existing supply chain inventory control strategies. Figure 6 illustrates the inventory state changes of the supply chain system under a closed-loop switching control strategy with Markov jump parameters [35]. Although both control strategies stabilize the system, the method proposed in this paper outperforms it in terms of control tracking accuracy, time required to reach stabilization, and the ability to mitigate the effects of disturbances. Furthermore, when compared to certain fuzzy-system-based methods [36,37], the T-S fuzzy switching control design based on the trust mechanism proposed here demonstrates enhanced capability in handling node failures, node update iterations, and other perturbations during system operation.
Figure 6.
Changes in inventory under traditional control methods: (a) inventory changes at the supplier nodes of subchains i, j, m; (b) inventory changes at the retailer nodes of subchains i, j, m; (c) inventory changes at the four nodes of subchain i; and (d) changes in consistency error among all nodes.
To verify the generalizability of the model and comprehensively evaluate its performance, we proceed to analyze its application across various industries with differing characteristics. Specifically, we assess the model’s impact on mitigating the bullwhip effect, enhancing cost-effectiveness, and improving lead-time indicators within the supply chain, using actual data for validation.
Take the fresh food and television factory industries as examples. The supply chain of the fresh food industry has a higher inventory loss rate, more stringent conditions required for storage, and needs to spend more on inventory costs, so it needs to keep the inventory in a lower state. Due to the short time period of goods storage and high real-time requirements, it is necessary to set a lower upper bound of interaction latency. At the same time, it should pay more attention to the production and sales of its own nodes to set the control scheme, so the scaling gain of the consistency controller should be reduced. TV industry products at all stages in the storage process are not easy to wear and tear, and the storage cost is lower, but when subjected to unforeseen events by the impact will be greater (such as the replacement of chip manufacturers, etc.). The node will spend a longer period of time in a broken state, so you need to ensure a higher inventory to withstand market turbulence. Due to the characteristics of larger reserves, longer production cycles, and greater impact by perturbations, the TV industry is more likely to have uneven distribution of goods between warehouses, so it is necessary to give the consistency of the protocol controller greater gain.
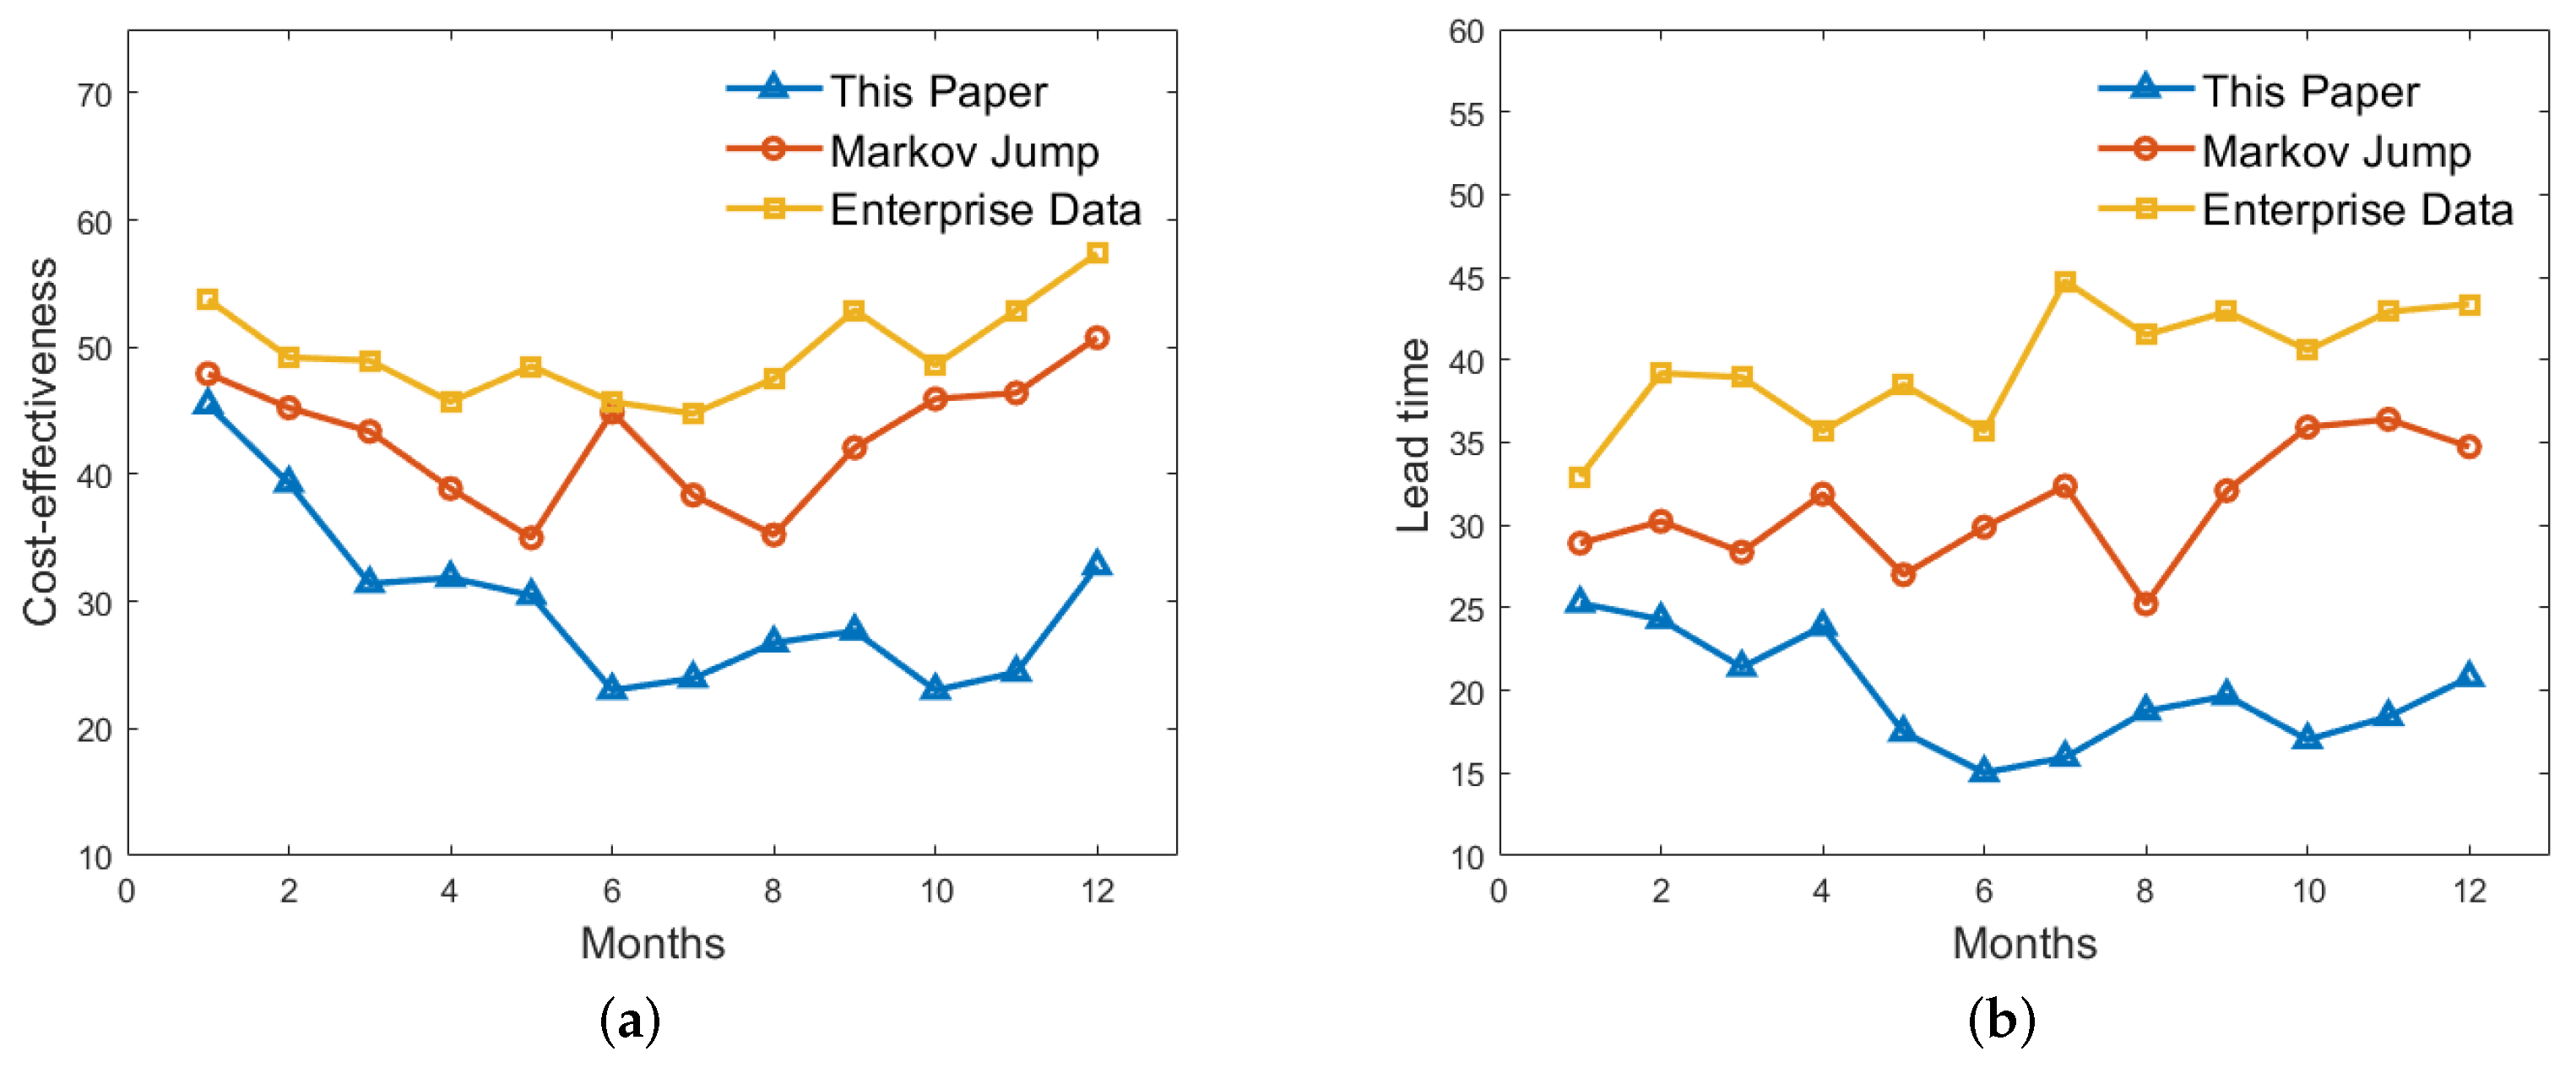
Taking the actual data in the supply chain operation of a domestic TV set manufacturer as an example, Figure 7 shows the impact on the cost-effectiveness and lead time of the supply chain under different control strategies. It can be seen that the method proposed in this paper has a better effect on reducing supply chain cost and improving supply chain efficiency.
Figure 7.
Supply chain performance indicators under different control strategies: (a) cost of inventory spent per month (unit: thousands of dollars); (b) average lead time per month (unit: days).
Table 2 presents the results comparing the impact of the bullwhip effect when applying the control method proposed in this paper versus the Markov jump control method, across different supply chain structures and varying inventory loss rates.
Table 2.
The bullwhip effect in different situations.
The results indicate that the method proposed in this paper outperforms the Markov jump method in suppressing the bullwhip effect. This improvement is particularly evident in application scenarios with high storage loss rates, such as the fresh food industry. Additionally, the proposed method demonstrates superior performance when more intelligence is integrated into the supply chain system.
6. Conclusions
This paper investigates the management problem when a supply chain breaks down due to unexpected events from a control theory perspective. The main objective of control is to minimize the economic cost and improve the supply efficiency in case of a smooth supply chain. For this, we modeled the supply chain system based on trust factors through a T-S fuzzy model and designed fuzzy controllers related to trust strength to reduce the impact of perturbations on the system due to node updating and replacing during the switching process of collaborative control. Meanwhile, the impact of the bullwhip effect is suppressed by control. A notable limitation of this study is its reliance on inventory-focused modeling and the authenticity of trust strength, which necessitates a collaborative supply chain ecosystem involving multiple parties. These constraints provide a foundation for future research directions.
Author Contributions
Methodology, Y.H. and Q.L.; validation, Y.H.; writing—original draft preparation, Y.H.; writing—review and editing, Y.H. All authors have read and agreed to the published version of the manuscript.
Funding
This research was funded by the National Key R&D Program of China of Qingkui Li under Grant 2020YFB1708200.
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
The raw data supporting the conclusions of this article will be made available by the authors on request.
Conflicts of Interest
The authors declare no conflicts of interest.
References
- Shah, H.M.; Gardas, B.B.; Narwane, V.S.; Mehta, H.S. The contemporary state of big data analytics and artificial intelligence towards intelligent supply chain risk management: A comprehensive review. Kybernetes 2023, 52, 1643–1697. [Google Scholar] [CrossRef] [Scilit]
- Xie, Y.; Yin, Y.; Xue, W.; Shi, H.; Chong, D. Intelligent supply chain performance measurement in Industry 4.0. Syst. Res. Behav. Sci. 2020, 37, 711–718. [Google Scholar] [CrossRef] [Scilit]
- Wu, Y.; Zhang, Y. An integrated framework for blockchain-enabled supply chain trust management towards smart manufacturing. Adv. Eng. Inform. 2022, 51, 101522. [Google Scholar] [CrossRef] [Scilit]
- Sarimveis, H.; Patrinos, P.; Tarantilis, C.D.; Kiranoudis, C.T. Dynamic modeling and control of supply chain systems: A review. Comput. Oper. Res. 2008, 35, 3530–3561. [Google Scholar] [CrossRef] [Scilit]
- Liu, L.; Chen, X. Conditional investment strategy in evolutionary trust games with repeated group interactions. Inf. Sci. 2022, 609, 1694–1705. [Google Scholar] [CrossRef] [Scilit]
- Zhang, X.; Lam, J.S.L. Measuring the Impact of E-Collaboration on Supply Chain Parties: A Value-Based Management Approach. IEEE Access 2021, 9, 118181–118193. [Google Scholar] [CrossRef] [Scilit]
- Pulikottil, T.; Estrada-Jimenez, L.A.; Rehman, H.U.; Barata, J.; Nikghadam-Hojjati, S.; Zarzycki, L. Multi-agent based manufacturing: Current trends and challenges. In Proceedings of the 2021 26th IEEE international conference on emerging technologies and factory automation (ETFA), Vasteras, Sweden, 7–10 September 2021; pp. 1–7. [Google Scholar]
- Dorri, A.; Kanhere, S.S.; Jurdak, R. Multi-agent systems: A survey. IEEE Access 2018, 6, 28573–28593. [Google Scholar] [CrossRef] [Scilit]
- Malik, S.; Dedeoglu, V.; Kanhere, S.S.; Jurdak, R. Trustchain: Trust management in blockchain and iot supported supply chains. In Proceedings of the 2019 IEEE International Conference on Blockchain (Blockchain), Atlanta, GA, USA, 14–17 July 2019; pp. 184–193. [Google Scholar]
- Jiang, R.; Kang, Y.; Liu, Y.; Liang, Z.; Duan, Y.; Sun, Y.; Liu, J. A trust transitivity model of small and medium-sized manufacturing enterprises under blockchain-based supply chain finance. Int. J. Prod. Econ. 2022, 247, 108469. [Google Scholar] [CrossRef] [Scilit]
- Zhang, H.; Nakamura, T.; Sakurai, K. Security and trust issues on digital supply chain. In Proceedings of the 2019 IEEE Intl Conf on Dependable, Autonomic and Secure Computing, Intl Conf on Pervasive Intelligence and Computing, Intl Conf on Cloud and Big Data Computing, Intl Conf on Cyber Science and Technology Congress (DASC/PiCom/CBDCom/CyberSciTech), Fukuoka, Japan, 5–8 August 2019; pp. 338–343. [Google Scholar]
- Ghadimi, P.; Wang, C.; Lim, M.K.; Heavey, C. Intelligent sustainable supplier selection using multi-agent technology: Theory and application for Industry 4.0 supply chains. Comput. Ind. Eng. 2019, 127, 588–600. [Google Scholar] [CrossRef] [Scilit]
- Shahzad, M.F.; Xu, S.; Baheer, R.; Ahmad, W. Unveiling the role of supply chain parameters approved by blockchain technology towards firm performance through trust: The moderating role of government support. Heliyon 2023, 9, e21831. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Pattanayak, S.; Ramkumar, M.; Goswami, M.; Rana, N.P. Blockchain technology and supply chain performance: The role of trust and relational capabilities. Int. J. Prod. Econ. 2024, 271, 109198. [Google Scholar] [CrossRef] [Scilit]
- Kiwala, Y.; Olivier, J.; Kintu, I. Antecedents and enablers of supply chain value creation: An analysis of trust and competences. Dev. South. Afr. 2023, 40, 580–598. [Google Scholar] [CrossRef] [Scilit]
- Kim, B.; Kim, J.G.; Lee, S. A multi-agent reinforcement learning model for inventory transshipments under supply chain disruption. IISE Trans. 2024, 56, 715–728. [Google Scholar] [CrossRef] [Scilit]
- Utama, D.M.; Santoso, I.; Hendrawan, Y.; Dania, W.A.P. Integrated procurement-production inventory model in supply chain: A systematic review. Oper. Res. Perspect. 2022, 9, 100221. [Google Scholar] [CrossRef] [Scilit]
- Pasupuleti, V.; Thuraka, B.; Kodete, C.S.; Malisetty, S. Enhancing supply chain agility and sustainability through machine learning: Optimization techniques for logistics and inventory management. Logistics 2024, 8, 73. [Google Scholar] [CrossRef] [Scilit]
- Du, J.; Jing, H.; Choo, K.K.R.; Sugumaran, V.; Castro-Lacouture, D. An ontology and multi-agent based decision support framework for prefabricated component supply chain. Inf. Syst. Front. 2020, 22, 1467–1485. [Google Scholar] [CrossRef] [Scilit]
- Fierro, L.H.; Cano, R.E.; García, J.I. Modelling of a multi-agent supply chain management system using Colored Petri Nets. Procedia Manuf. 2020, 42, 288–295. [Google Scholar] [CrossRef] [Scilit]
- Li, Q.K.; Lin, H.; Tan, X.; Du, S. H∞ consensus for multiagent-based supply chain systems under switching topology and uncertain demands. IEEE Trans. Syst. Man Cybern. Syst. 2018, 50, 4905–4918. [Google Scholar] [CrossRef] [Scilit]
- Khokhar, M.; Zia, S.; Khan, S.A.; Saleem, S.T.; Siddiqui, A.A.; Abbas, M. Decision Support System for Safety Stock and Safety Time Buffers in Multi-Item Single-Stage Industrial Supply Chains. Int. J. Inf. Syst. Soc. Chang. 2023, 14, 1–13. [Google Scholar] [CrossRef] [Scilit]
- Tseng, C.S.; Chen, B.S.; Uang, H.J. Fuzzy tracking control design for nonlinear dynamic systems via TS fuzzy model. IEEE Trans. Fuzzy Syst. 2001, 9, 381–392. [Google Scholar] [CrossRef] [Scilit]
- Wang, J.; Chang, Q.; Gao, T.; Zhang, K.; Pal, N.R. Sensitivity analysis of Takagi–Sugeno fuzzy neural network. Inf. Sci. 2022, 582, 725–749. [Google Scholar] [CrossRef] [Scilit]
- Aslam, M.S.; Tiwari, P.; Pandey, H.M.; Band, S.S. Robust stability analysis for class of Takagi-Sugeno (TS) fuzzy with stochastic process for sustainable hypersonic vehicles. Inf. Sci. 2023, 641, 119044. [Google Scholar] [CrossRef] [Scilit]
- Bhattacharya, R.; Bandyopadhyay, S. A review of the causes of bullwhip effect in a supply chain. Int. J. Adv. Manuf. Technol. 2011, 54, 1245–1261. [Google Scholar] [CrossRef] [Scilit]
- Lee, H.L.; Padmanabhan, V.; Whang, S. The bullwhip effect in supply chains. Sloan Manag. Rev. 1997, 38, 93–102. [Google Scholar] [CrossRef] [Scilit]
- Wang, X.; Disney, S.M. The bullwhip effect: Progress, trends and directions. Eur. J. Oper. Res. 2016, 250, 691–701. [Google Scholar] [CrossRef] [Scilit]
- Huang, X.Y.; Yan, N.N.; Guo, H.F. An H∞ control method of the bullwhip effect for a class of supply chain system. Int. J. Prod. Res. 2007, 45, 207–226. [Google Scholar] [CrossRef] [Scilit]
- Fawcett, S.E.; Jones, S.L.; Fawcett, A.M. Supply chain trust: The catalyst for collaborative innovation. Bus. Horizons 2012, 55, 163–178. [Google Scholar] [CrossRef] [Scilit]
- Ouzrout, Y.; Chaze, L.; Lavastre, O.; Dominguez, C.; Akhter, S.H. Simulation of trust in supply chains. In Supply Chain Performance: Collaboration, Alignment and Coordination; John Wiley & Sons, Inc.: Hoboken, NJ, USA, 2013; pp. 267–315. [Google Scholar]
- Moon, Y.S.; Park, P.; Kwon, W.H.; Lee, Y.S. Delay-dependent robust stabilization of uncertain state-delayed systems. Int. J. Control 2001, 74, 1447–1455. [Google Scholar] [CrossRef] [Scilit]
- Li, J.; Chen, Z.; Cai, D.; Zhen, W.; Huang, Q. Delay-dependent stability control for power system with multiple time-delays. IEEE Trans. Power Syst. 2015, 31, 2316–2326. [Google Scholar] [CrossRef] [Scilit]
- Rodrigues, L.; Boukas, E.K. Piecewise-linear H∞ controller synthesis with applications to inventory control of switched production systems. Automatica 2006, 42, 1245–1254. [Google Scholar] [CrossRef] [Scilit]
- Aditya, I.; Simaremare, A.A.; Hudaya, C. Study of Coal Inventory Planning Analysis in a coal-fired power plant using continuous and Periodic Review. In Proceedings of the 2019 IEEE 2nd International Conference on Power and Energy Applications (ICPEA), Singapore, 27–30 April 2019; pp. 33–36. [Google Scholar]
- Luan, T.; Sun, M.; Hu, Z.; Fu, Q.; Wang, H. A novel TS fuzzy robust control for part transportation of aircraft carrier considering transportation time and stochastic demand. Aerosp. Sci. Technol. 2021, 119, 107096. [Google Scholar] [CrossRef] [Scilit]
- Goodarzian, F.; Ghasemi, P.; Gunasekaran, A.; Labib, A. A fuzzy sustainable model for COVID-19 medical waste supply chain network. Fuzzy Optim. Decis. Mak. 2024, 23, 93–127. [Google Scholar] [CrossRef] [Scilit]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2024 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).