Morphology-Guided Nonlinear Structural Evaluation of a Hybrid Bio-Inspired Soft Robotic Actuator

 ,
 ,
 , , and
Abstract
1. Introduction
2. Materials and Methods
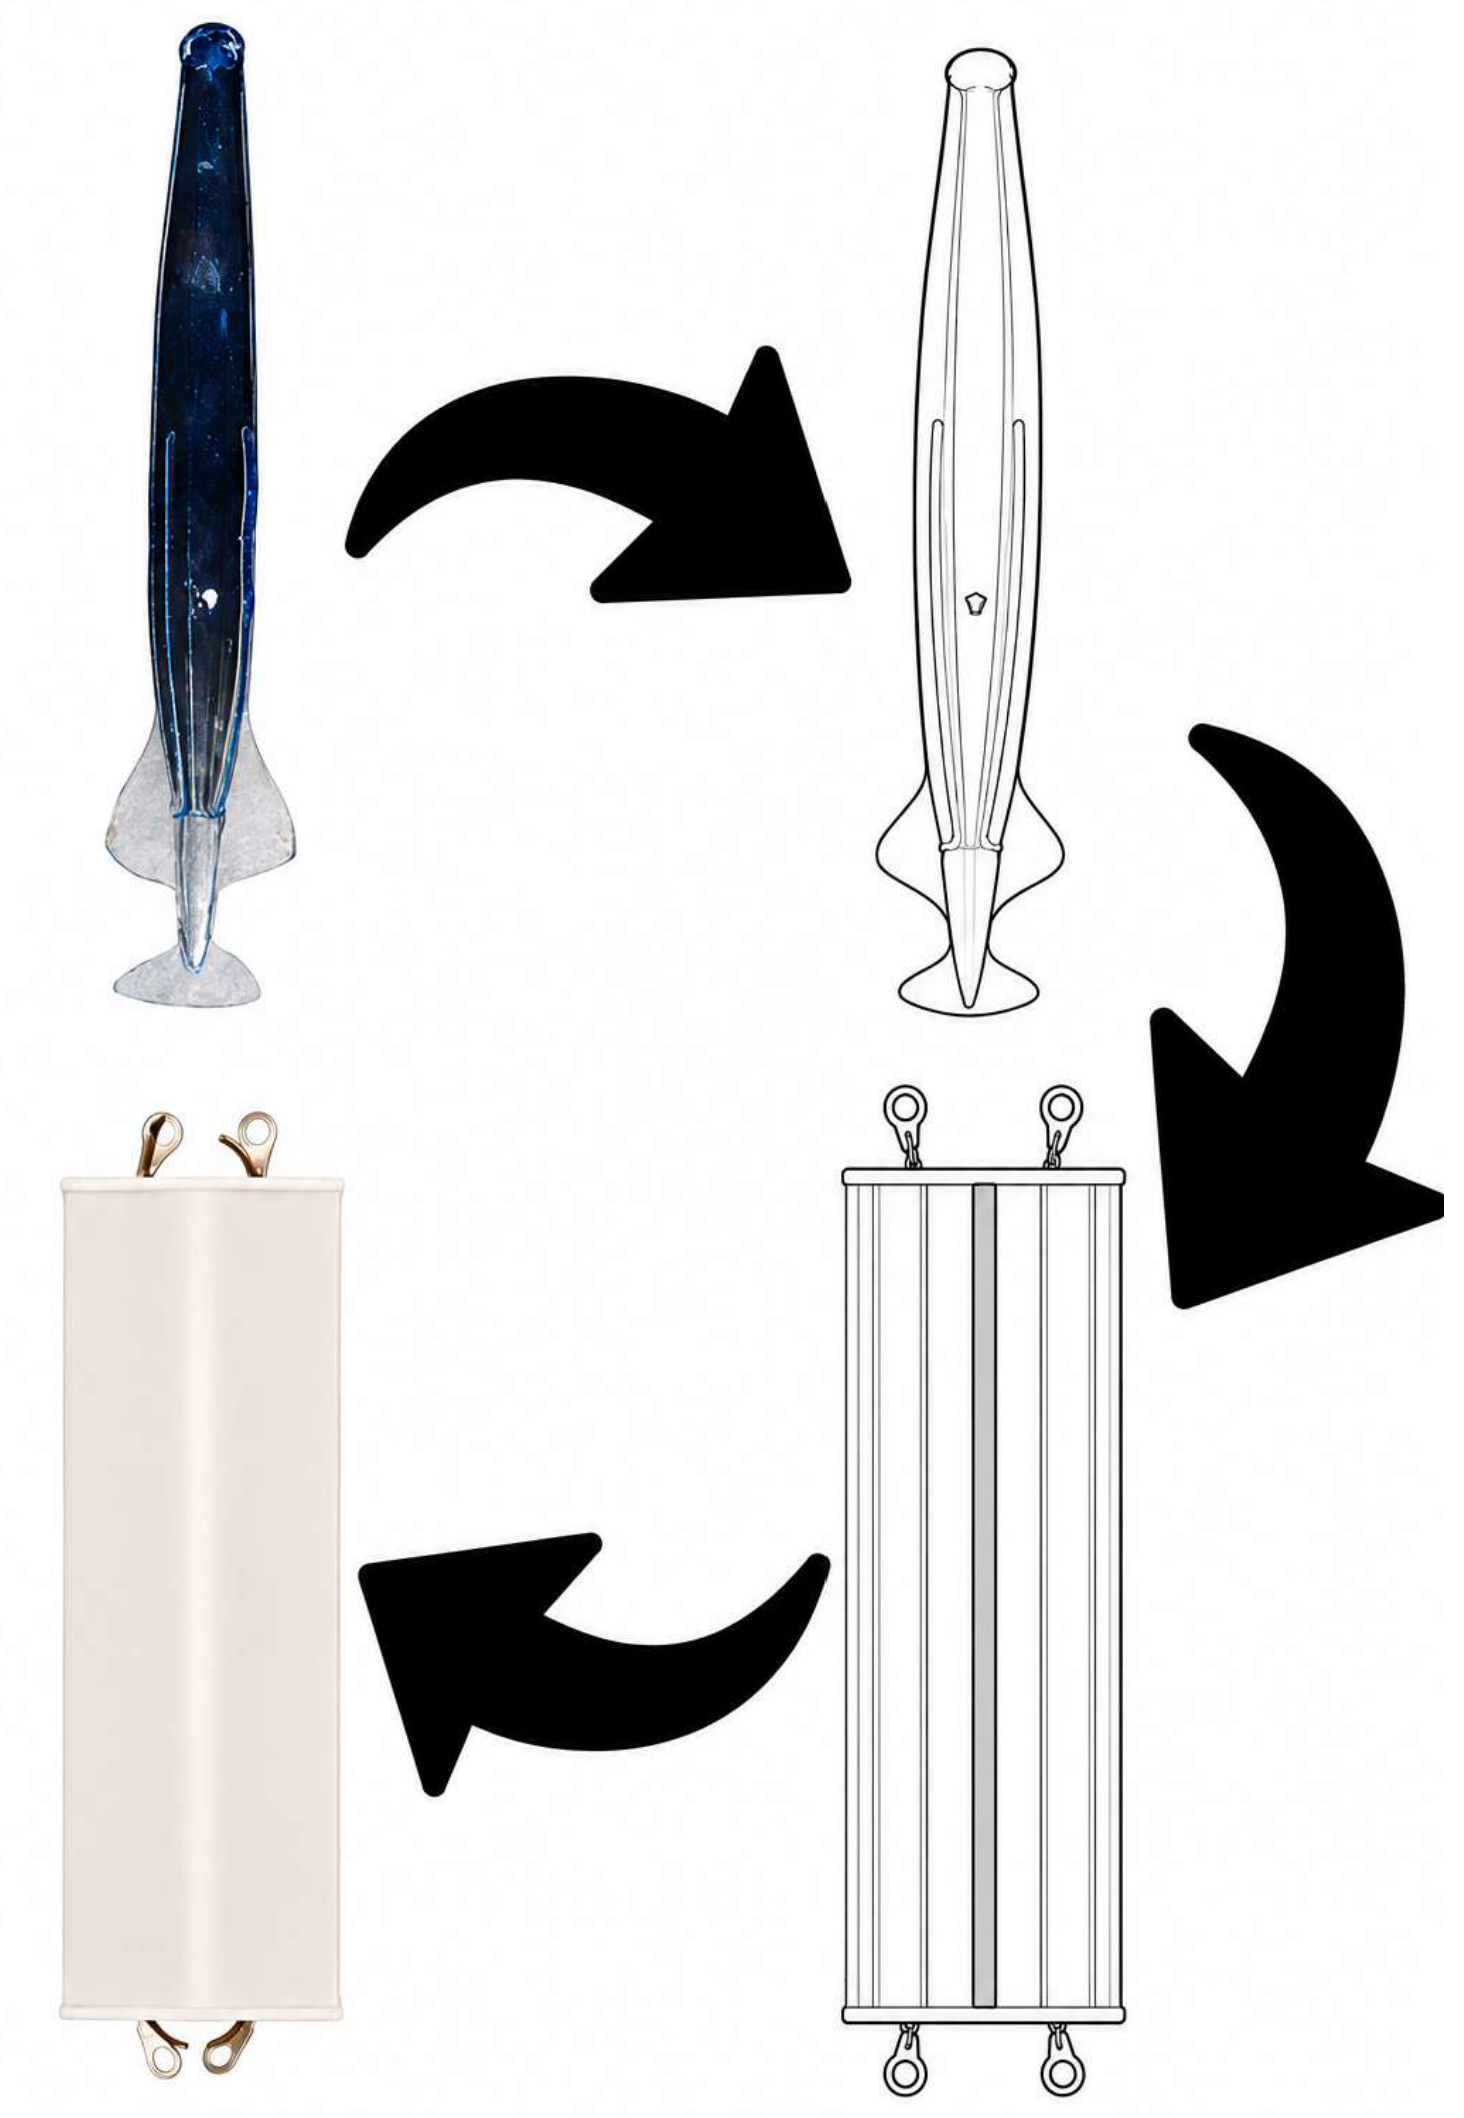
2.1. Bio-Inspiration in Actuator Design
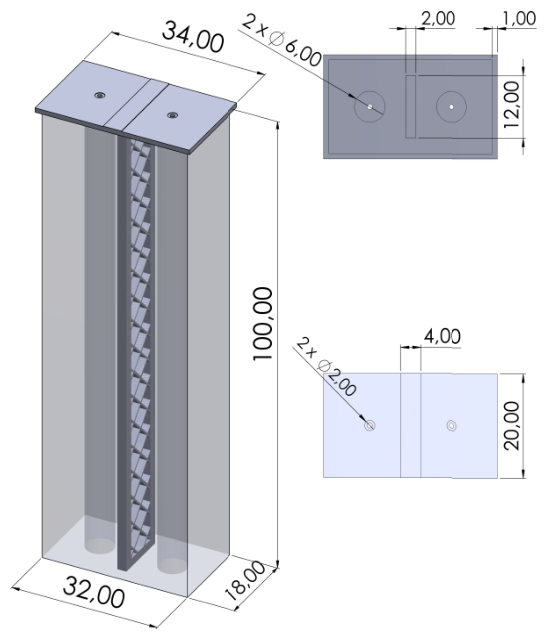
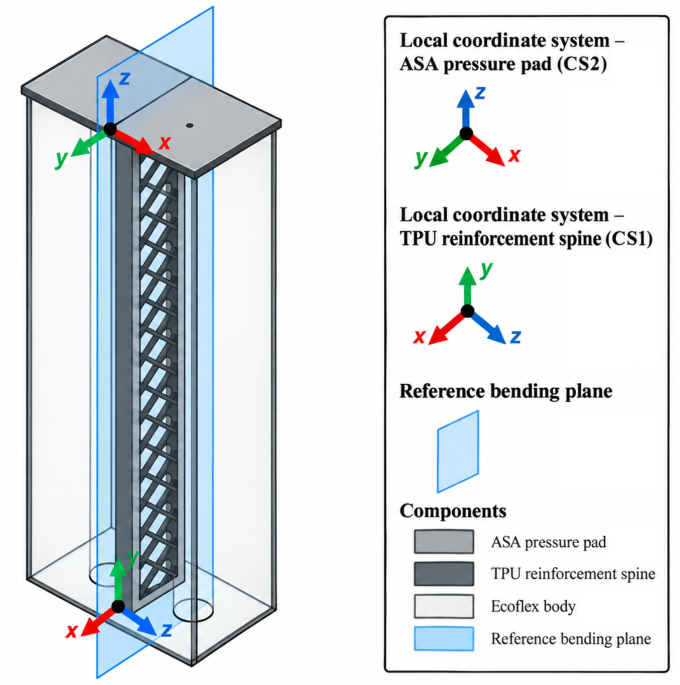
2.2. Conceptual and Mechanical Design
2.2.1. SMA Spring Representation and Model Scope
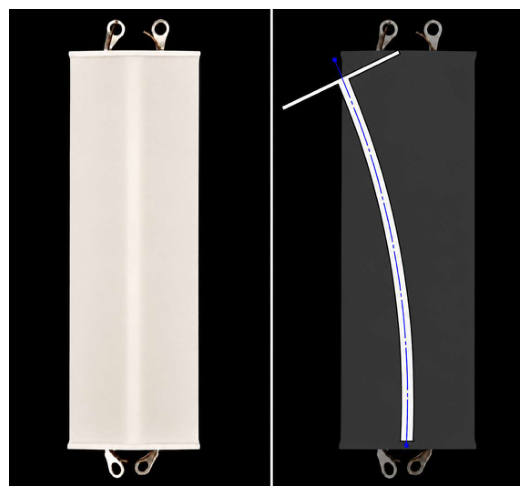
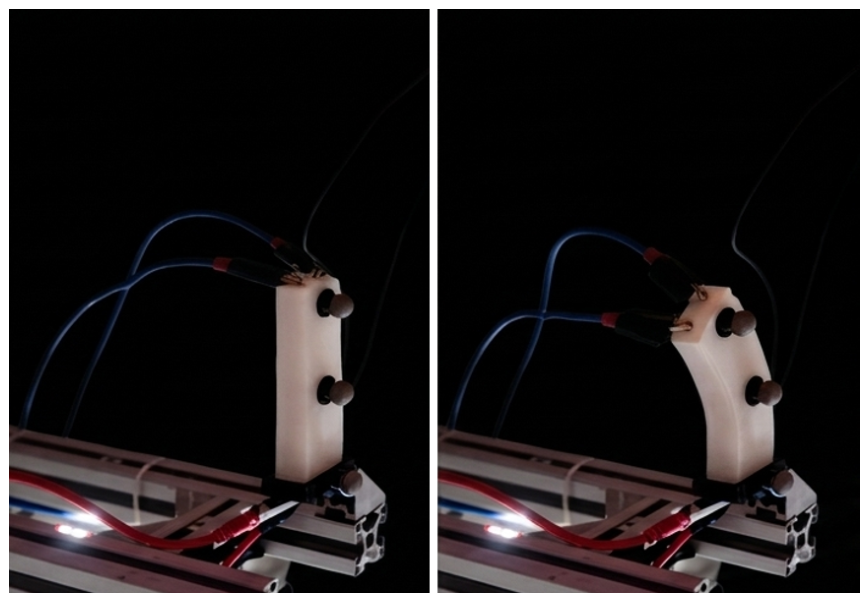
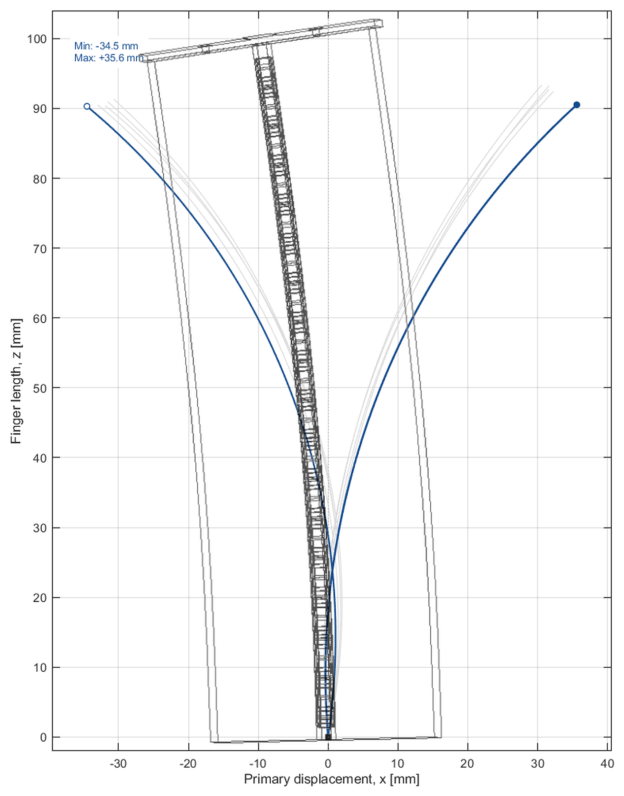
2.2.2. Existing Experimental Reference Configuration
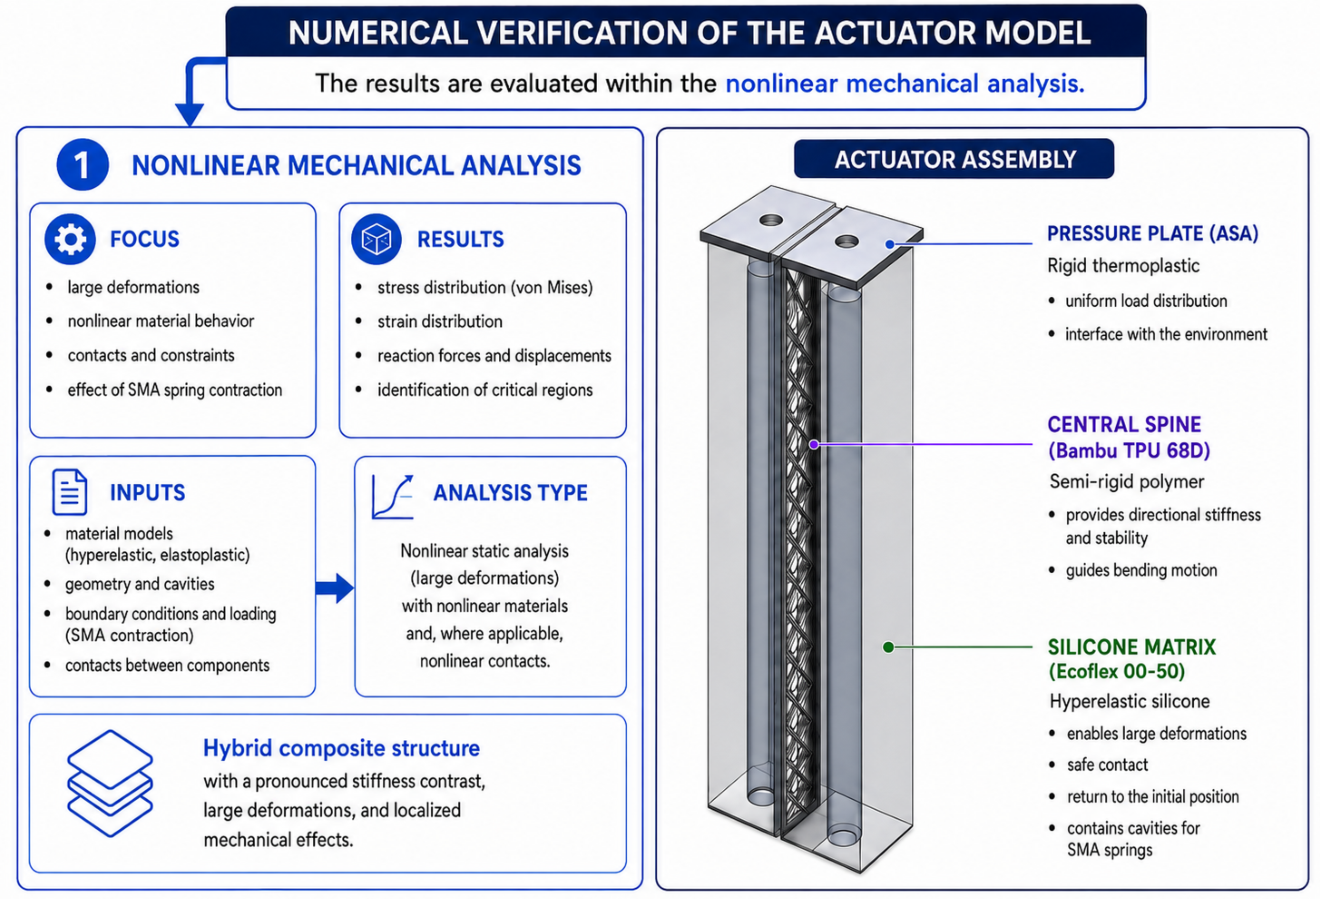
2.3. Nonlinear Finite Element Model and Numerical Procedure
2.4. Solving a Nonlinear Static Problem

| Material | Model | Key Parameters |
|---|---|---|
| EcoflexTM 00-50 1 | Hyperelastic–Ogden | kg/m3, , K−1, Power coefficients : , Ogden constants : MPa |
| ASA 2 | Linear elastic orthotropic | GPa, GPa, GPa, GPa, GPa, kg/m3, , , K−1, K−1 |
| Bambu TPU 68D 3 | Linear elastic orthotropic | GPa, GPa, GPa, GPa, kg/m3, , K−1 |
| Parameter Area | Settings |
|---|---|
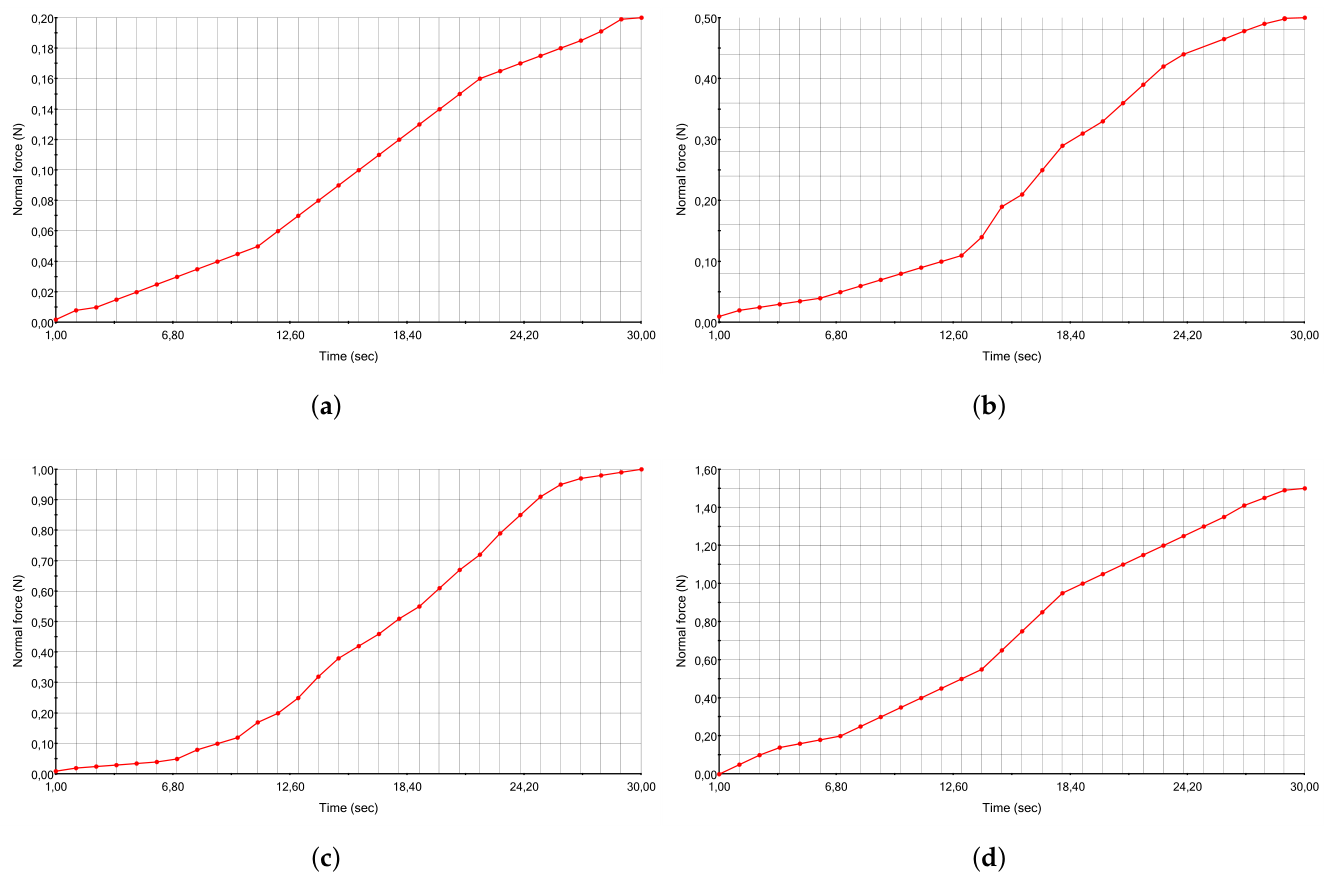
| Type of problem being solved | Nonlinear–Static; 0–30 s; step 1 s |
| Geometry nonlinearity options | Large displacement formulation; Large strain option |
| Thermal effect | Temperature loads included; Zero strain at 298 K |
| Solver | Large Problem Direct Sparse; Force control; Newton–Raphson |
| Material model | EcoflexTM 00-50 as a hyperelastic Ogden model; TPU and ASA as orthotropic polymer materials |
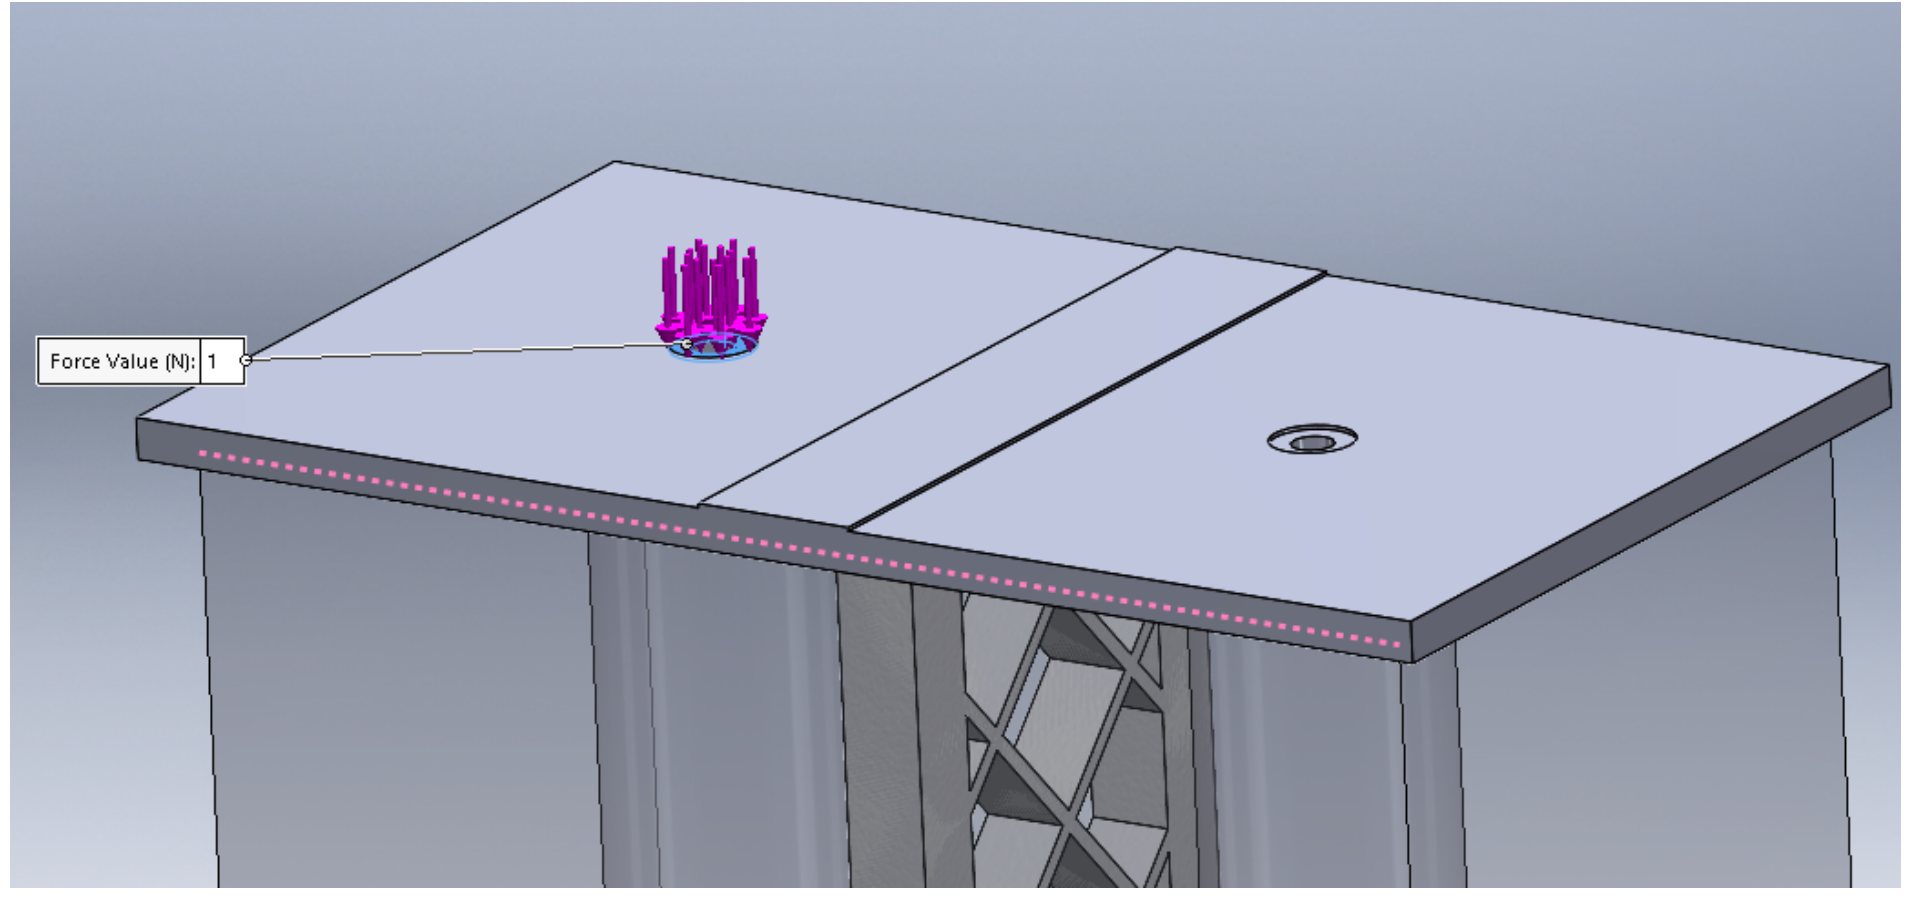
| Boundary conditions | 2 fixed surfaces; 1 surface with actuation force and time curve 1 |
| Bonds and contacts of materials | Bonded interactions; the model assumes continuous strain transfer between materials without interface separation |
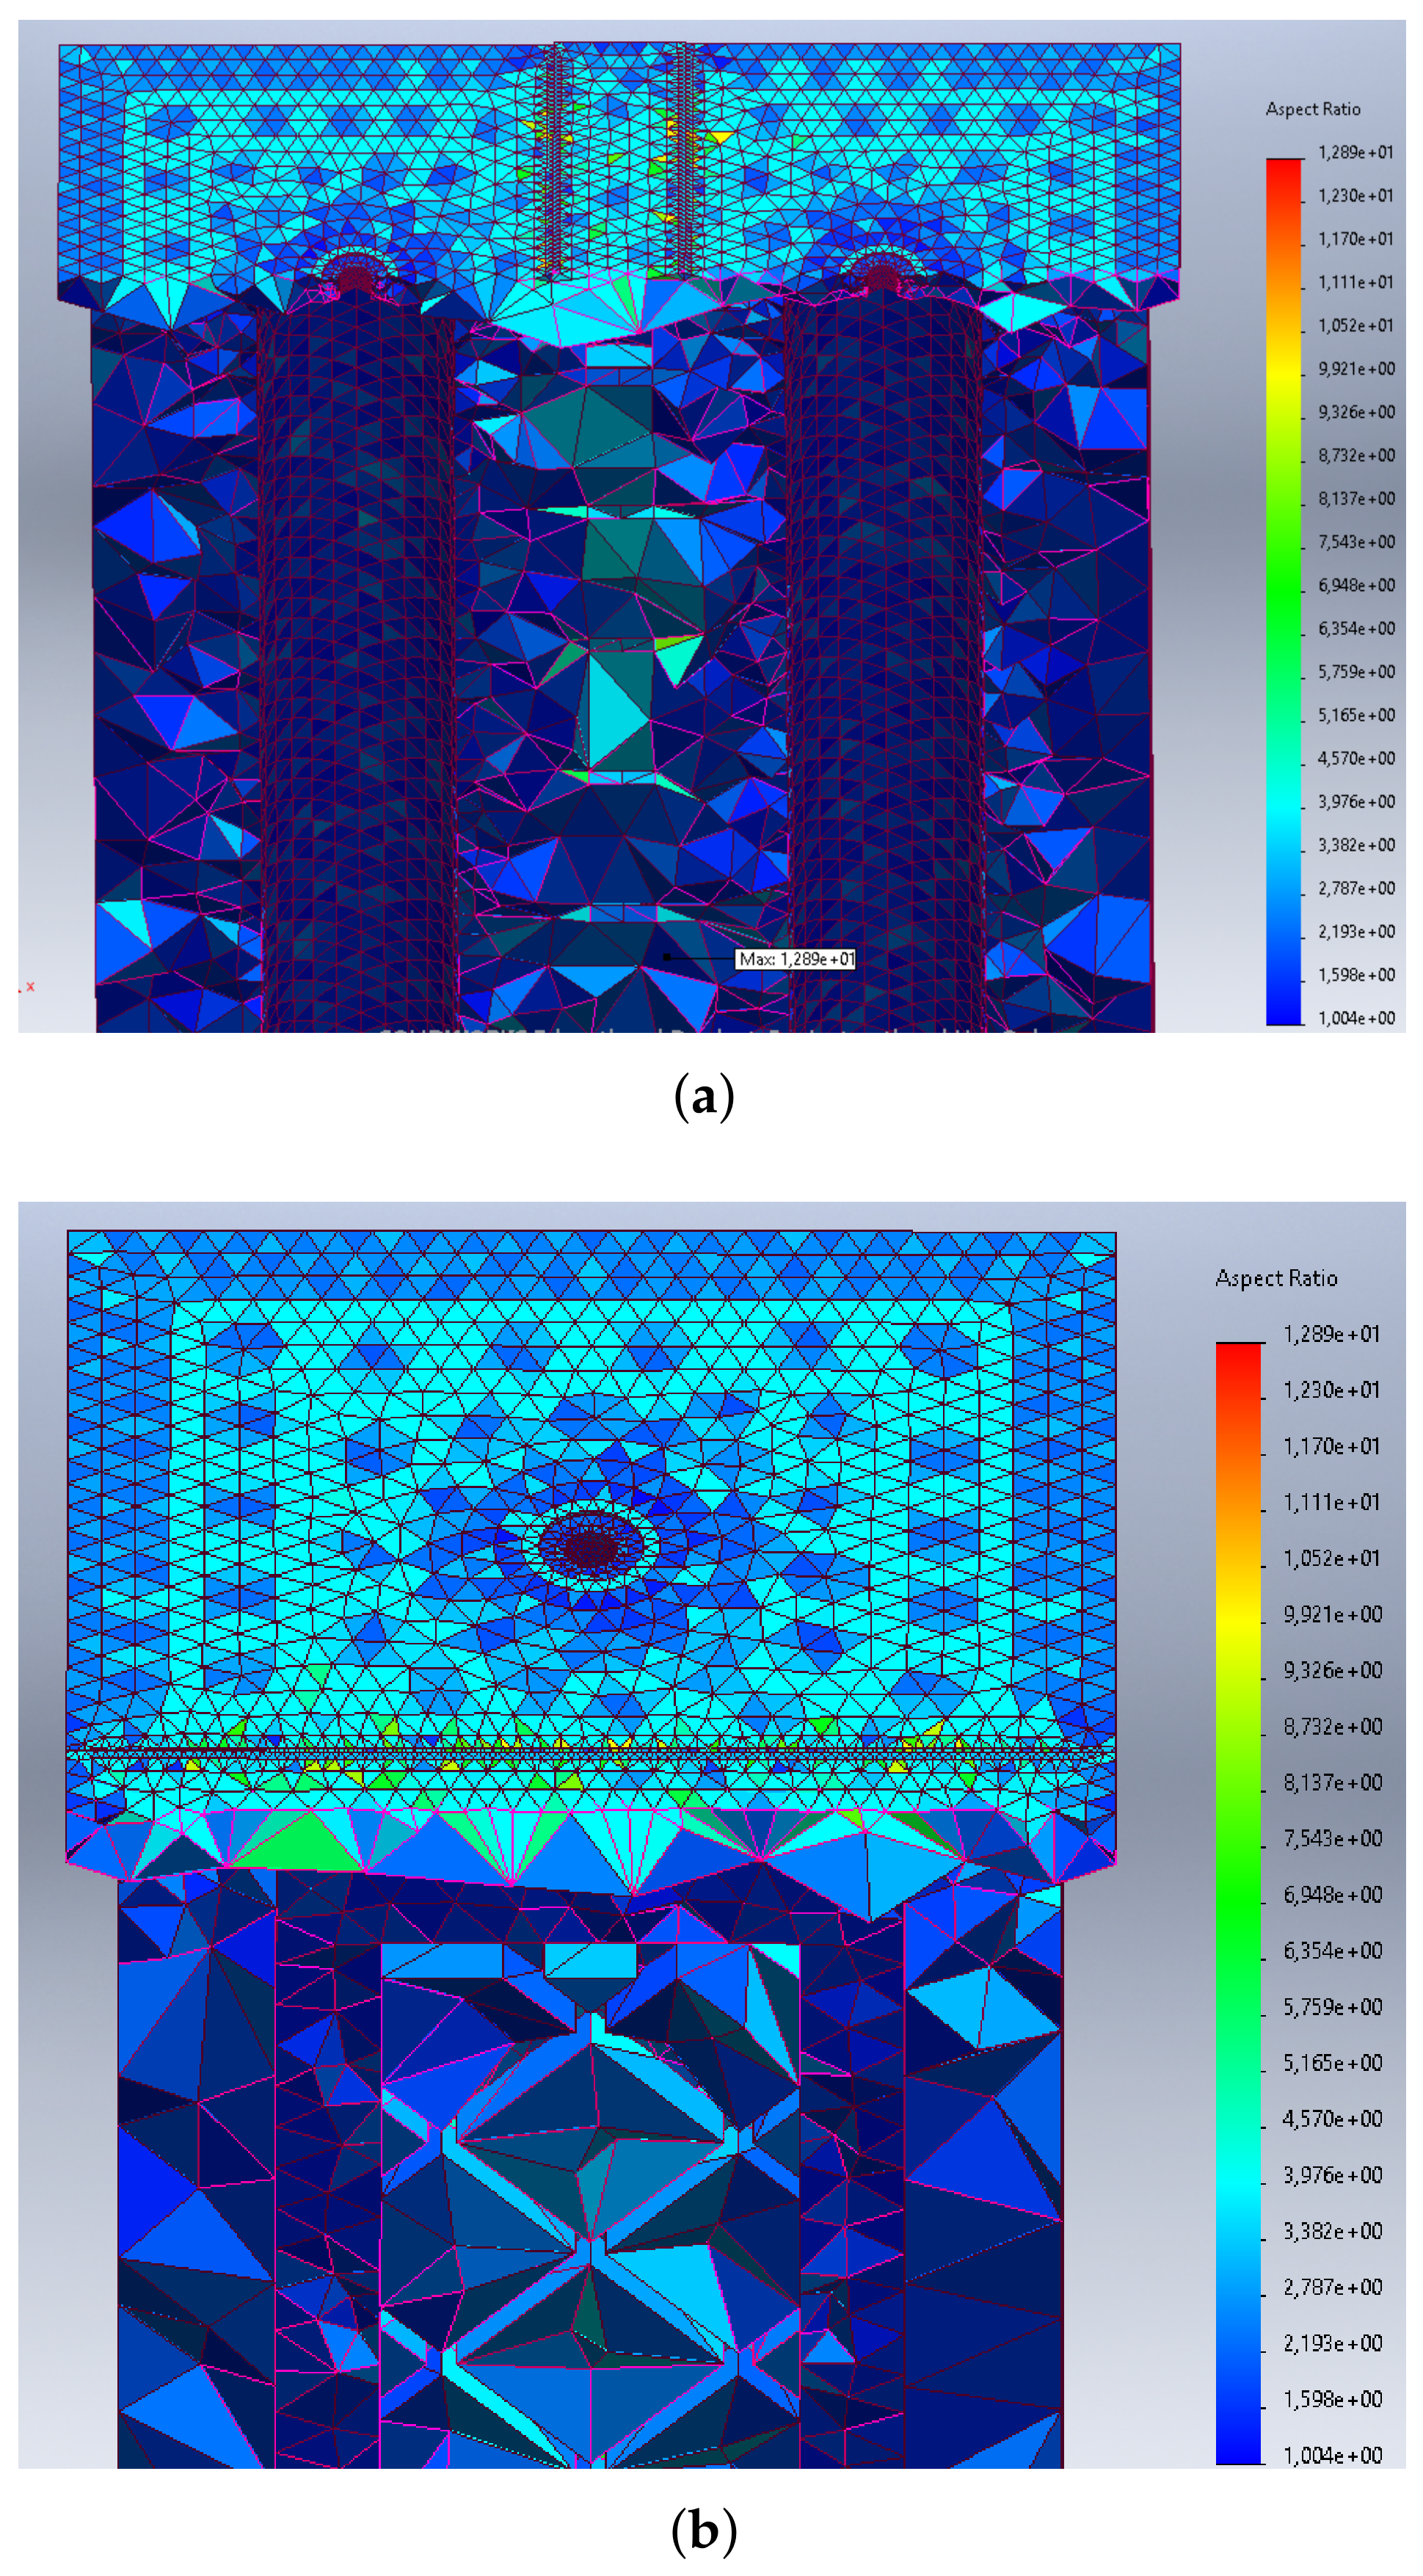
| Mesh | Blended curvature-based solid mesh; 226,198 nodes and 142,836 elements, no distorted elements |
Representative Experimental–Numerical Comparison Protocol
2.5. Morphological Computational Algorithm Methodology
3. Results
3.1. Results of Nonlinear Static Analysis
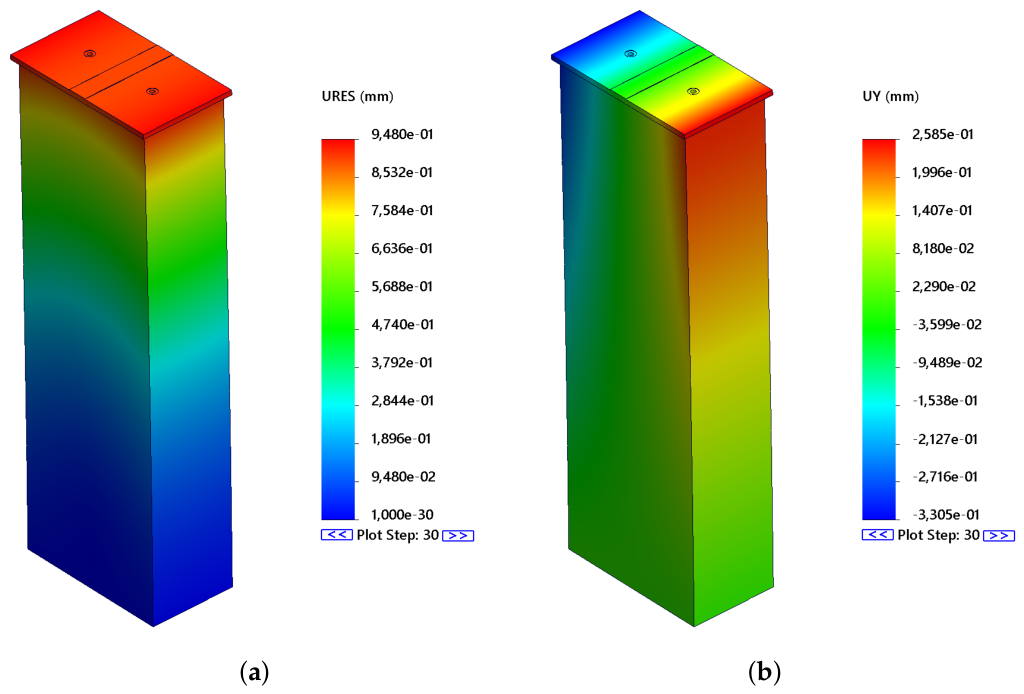
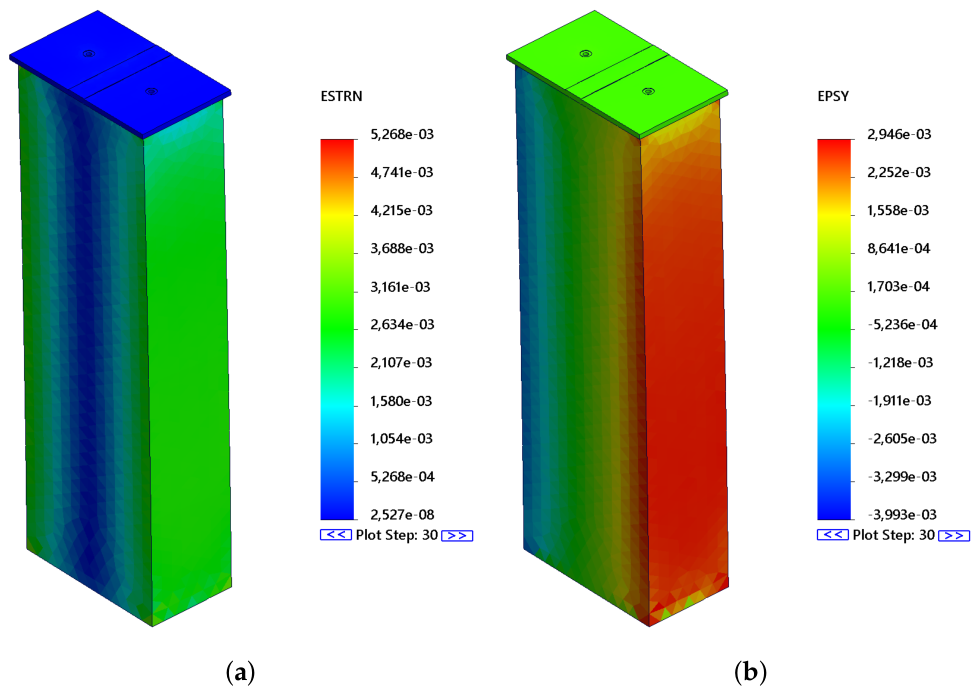
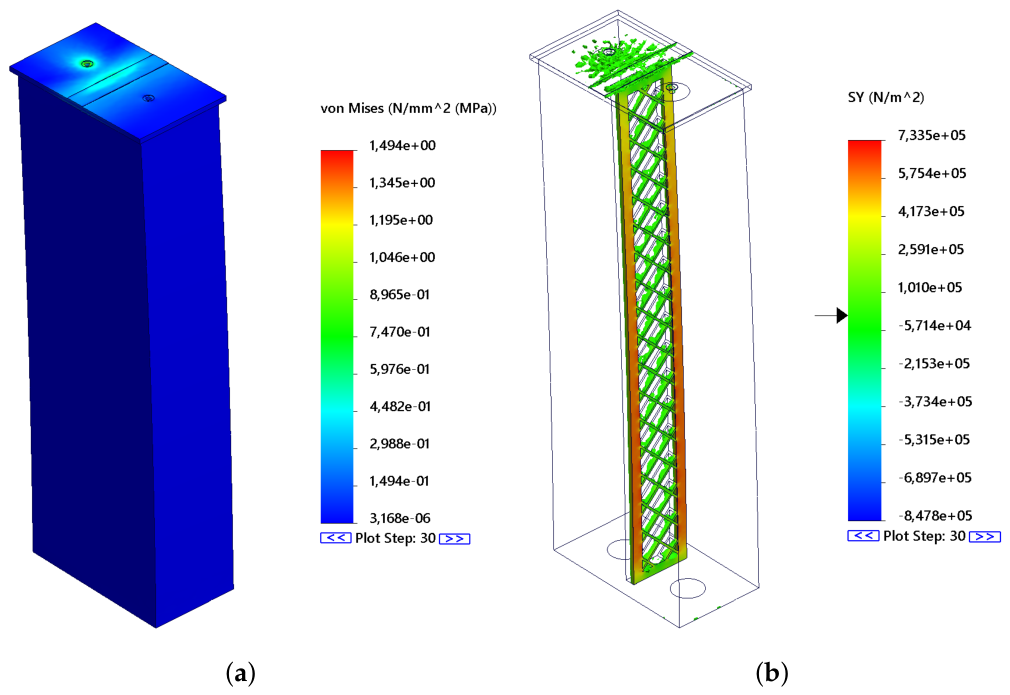
3.1.1. Results of Nonlinear Study I
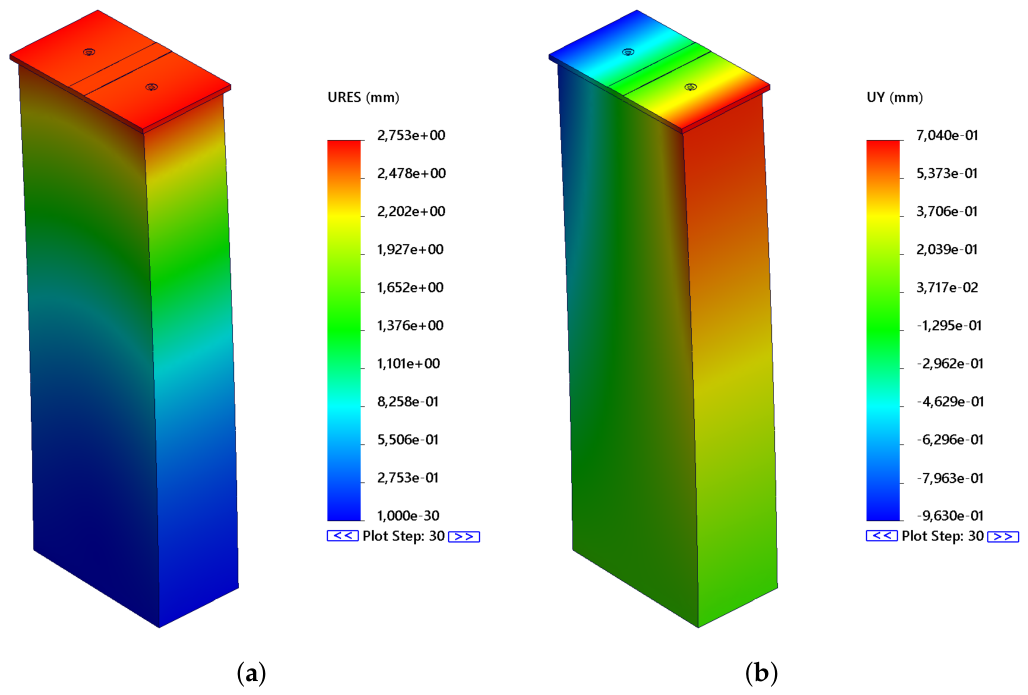
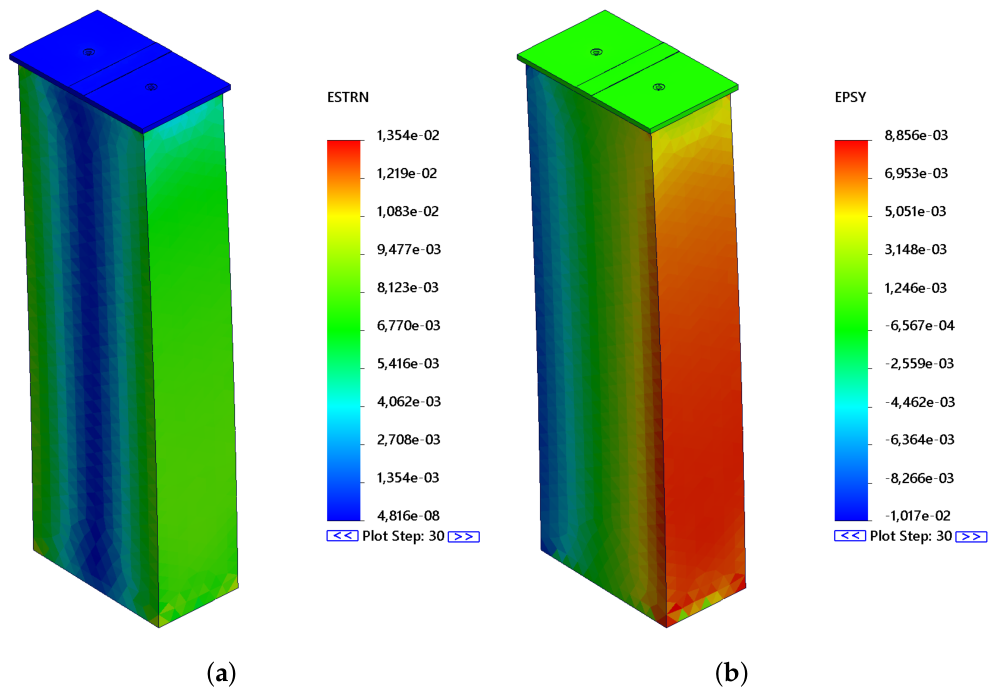
3.1.2. Results of Nonlinear Study II
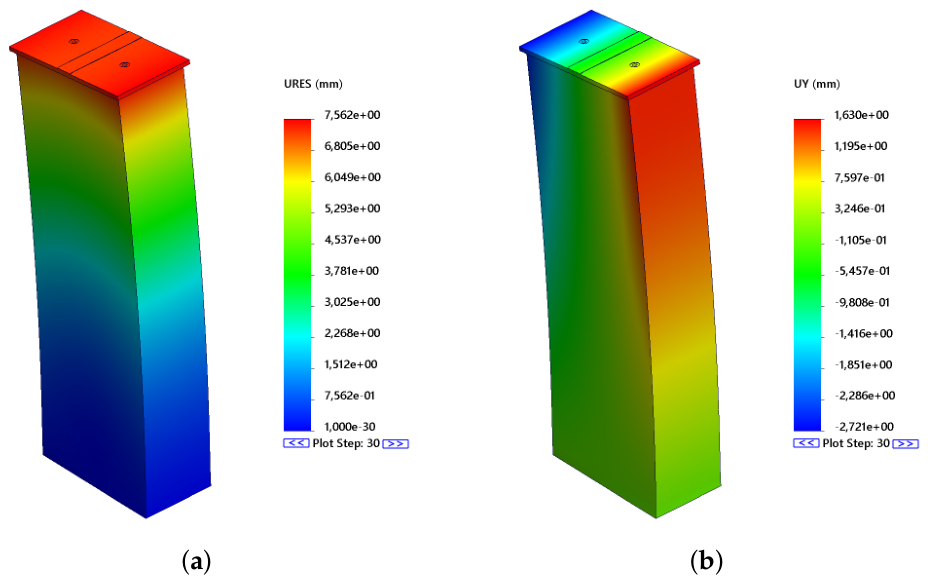
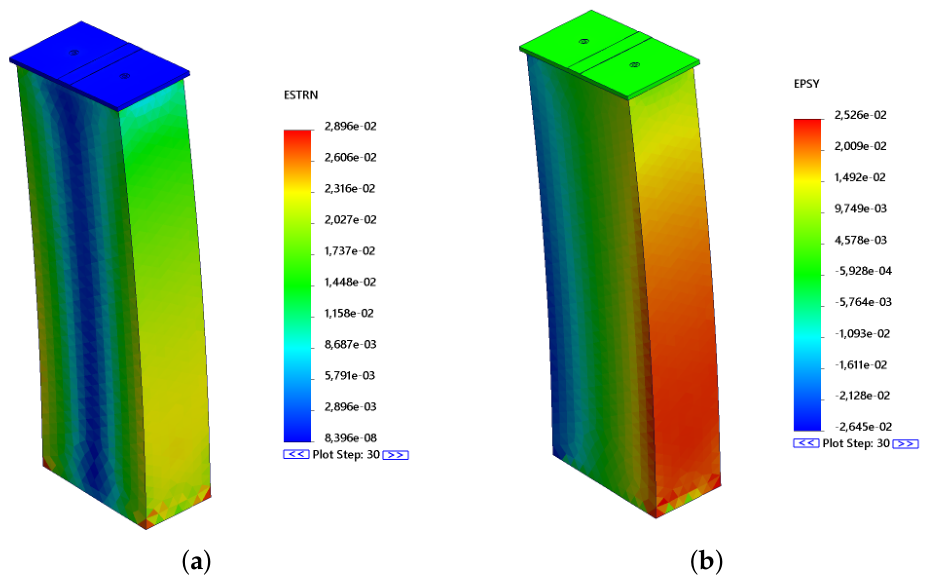
3.1.3. Results of Nonlinear Study III
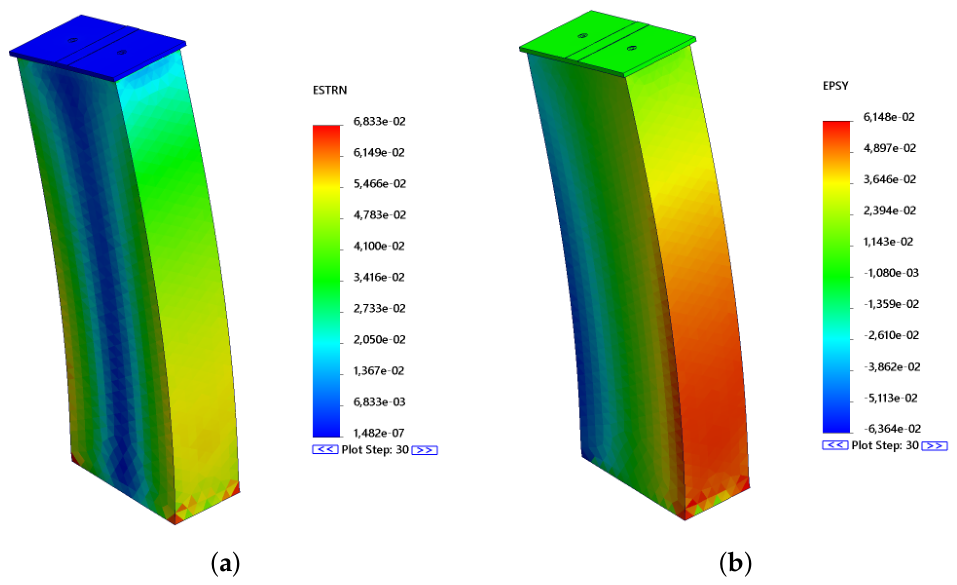
3.1.4. Results of Nonlinear Study IV
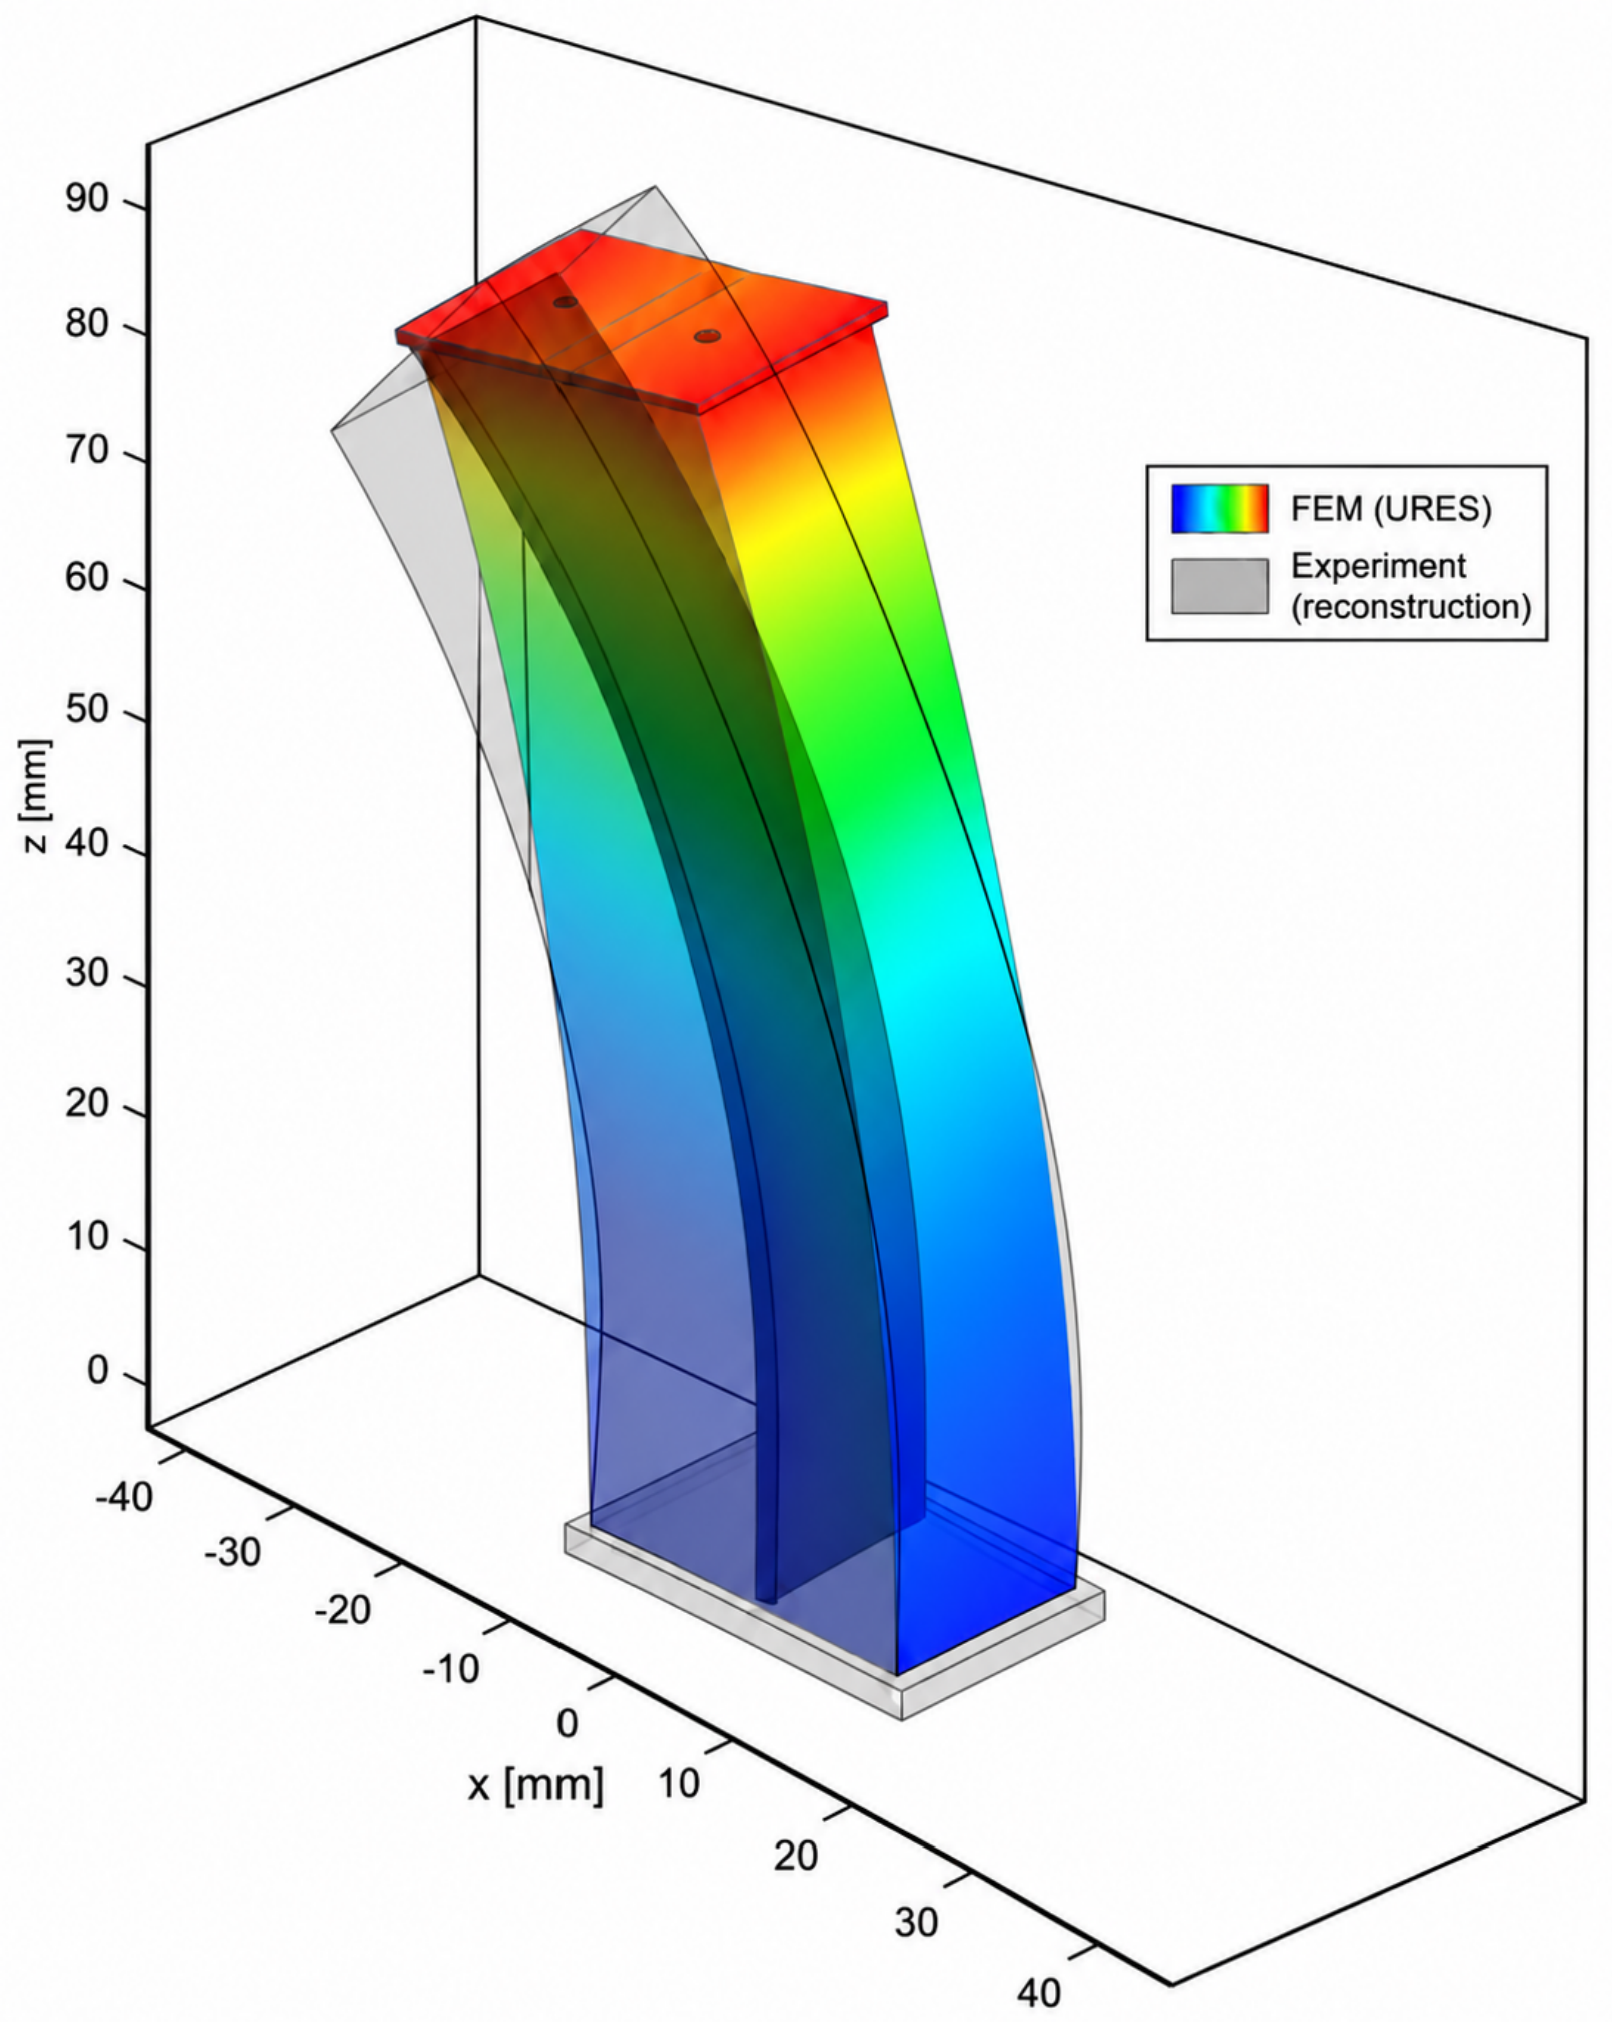
3.1.5. Representative Experimental–Numerical Comparison
3.2. Morphology-Guided Response and Design-Level Interpretation of the FEA Fields
3.3. Morphological Calculation Results
4. Discussion
5. Conclusions
Author Contributions
Funding
Institutional Review Board Statement
Informed Consent Statement
Data Availability Statement
Acknowledgments
Conflicts of Interest
Appendix A
| Algorithm A1 Reference-Morphology Nonlinear Response Mapping Algorithm |
|
References
- Rus, D.; Tolley, M.T. Design, fabrication and control of soft robots. Nature 2015, 521, 467–475. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Trivedi, D.; Rahn, C.D.; Kier, W.M.; Walker, I.D. Soft Robotics: Biological Inspiration, State of the Art, and Future Research. Appl. Bionics Biomech. 2008, 5, 99–117. [Google Scholar] [CrossRef]
- Havlik, S.; Hricko, J. Soft Grasping Delicate Parts by Robotic Effectors. In Advances in Service and Industrial Robotics; Springer: Cham, Switzerland, 2024; Volume 157, pp. 639–646. [Google Scholar] [CrossRef] [Scilit]
- Pfeifer, R.; Iida, F.; G’omez, G. Morphological computation for adaptive behavior and cognition. Int. Congr. Ser. 2006, 1291, 22–29. [Google Scholar] [CrossRef] [Scilit]
- Mengaldo, G.; Renda, F.; Brunton, S.L.; Bächer, M.; Calisti, M.; Duriez, C.; Chirikjian, G.S.; Laschi, C. A concise guide to modelling the physics of embodied intelligence in soft robotics. Nat. Rev. Phys. 2022, 4, 595–610. [Google Scholar] [CrossRef] [Scilit]
- Li, M.; Pal, A.; Aghakhani, A.; Pena-Francesch, A.; Sitti, M. Soft actuators for real-world applications. Nat. Rev. Mater. 2022, 7, 235–249. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Connolly, F.; Polygerinos, P.; Walsh, C.J.; Bertoldi, K. Mechanical programming of soft actuators by varying fiber angle. Soft Robot. 2015, 2, 26–32. [Google Scholar] [CrossRef] [Scilit]
- Connolly, F.; Walsh, C.J.; Bertoldi, K. Automatic design of fiber-reinforced soft actuators for trajectory matching. Proc. Natl. Acad. Sci. USA 2017, 114, 51–56. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Schaffner, M.; Faber, J.A.; Pianegonda, L.; Rühs, P.A.; Coulter, F.; Studart, A.R. 3D printing of robotic soft actuators with programmable bioinspired architectures. Nat. Commun. 2018, 9, 878. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Manti, M.; Cacucciolo, V.; Cianchetti, M. Stiffening in soft robotics: A review of the state of the art. IEEE Robot. Autom. Mag. 2016, 23, 93–106. [Google Scholar] [CrossRef] [Scilit]
- Shan, Y.; Zhao, Y.; Wang, H.; Dong, L.; Pei, C.; Jin, Z.; Sun, Y.; Liu, T. Variable stiffness soft robotic gripper: Design, development, and prospects. Bioinspir. Biomim. 2024, 19, 011001. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Garcia, E. Smart structures and actuators: Past, present, and future. In Proceedings of the SPIE 4698, Smart Structures and Materials 2002: Industrial and Commercial Applications of Smart Structures Technologies, San Diego, CA, USA, 9 July 2002. [Google Scholar] [CrossRef] [Scilit]
- Do, X.P.; Choi, S.-B. A state-of-the-art on smart materials actuators over the last decade: Control aspects for diverse applications. Smart Mater. Struct. 2022, 31, 053001. [Google Scholar] [CrossRef] [Scilit]
- Funakubo, H. Shape Memory Alloys; Gordon and Breach Science Publishers: New York, NY, USA, 1987. [Google Scholar]
- Wadood, A. Brief Overview on Nitinol as Biomaterial. Adv. Mater. Sci. Eng. 2016, 4173138. [Google Scholar] [CrossRef] [Scilit]
- Kim, M.-S.; Heo, J.-K.; Rodrigue, H.; Lee, H.-T.; Pané, S.; Han, M.-W.; Ahn, S.-H. Shape Memory Alloy (SMA) Actuators: The Role of Material, Form, and Scaling Effects. Adv. Mater. 2023, 35, 2208517. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Huang, W. On the selection of shape memory alloys for actuators. Mater. Des. 2002, 23, 11–19. [Google Scholar] [CrossRef] [Scilit]
- Kim, H.; Han, M.; Wang, W.; Song, S.; Rodrigue, H.; Ahn, S. Design and development of bio-mimetic soft robotic hand with shape memory alloy. In Proceedings of the IEEE International Conference on Robotics and Biomimetics (ROBIO), Zhuhai, China, 6–9 December 2015; pp. 2330–2334. [Google Scholar] [CrossRef] [Scilit]
- Kim, H.; Han, M.; Song, S.; Ahn, S. Soft Morphing Hand Driven by SMA Tendon Wire. Compos. Part B Eng. 2016, 105, 138–148. [Google Scholar] [CrossRef] [Scilit]
- Sadeghi, M.; Abbasimoshaei, A.; Borges, J.P.K.; Kern, T.A. Numerical and Experimental Study of a Wearable Exo-Glove for Telerehabilitation Application Using Shape Memory Alloy Actuators. Actuators 2024, 13, 409. [Google Scholar] [CrossRef] [Scilit]
- Sanadhya, A.; Chandak, K.; Gohil, J.; Trivedi, R.; Roy, D.; Parikh, P.; Chauhan, M.; Patel, K. Advancements in Finger Prosthesis: A Design Using Shape Memory Alloy Actuation Mechanism. Results Eng. 2025, 27, 105050. [Google Scholar] [CrossRef] [Scilit]
- Ma, J.; Huang, H.; Huang, J. Characteristics Analysis and Testing of SMA Spring Actuator. Adv. Mater. Sci. Eng. 2013. [Google Scholar] [CrossRef] [Scilit]
- De Laurentis, K.J.; Fisch, A.; Nikitczuk, J.; Mavroidis, C. Optimal Design of Shape Memory Alloy Wire Bundle Actuators. In Proceedings of the IEEE International Conference on Robotics and Automation (ICRA), Washington, DC, USA, 11–15 May 2002. [Google Scholar] [CrossRef] [Scilit]
- Guadalupe, J.A.; Copaci, D.; Navarro, P.M.; Moreno, L.; Blanco, D. A Novel Multi-Wire SMA-Based Actuator with High-Frequency Displacement. Mechatronics 2023, 91, 102957. [Google Scholar] [CrossRef] [Scilit]
- Liu, Q.; Ghodrat, S.; Jansen, K.M.B. Design and modelling of a reversible shape memory alloy torsion hinge actuator. Mater. Des. 2024, 237, 112590. [Google Scholar] [CrossRef] [Scilit]
- Lu, A.; Grant, D.; Hayward, V. Design and comparison of high strain shape memory alloy actuators. In Proceedings of the 1997 IEEE International Conference on Robotics and Automation (ICRA), Albuquerque, NM, USA, 20–25 April 1997; Volume 1, pp. 260–265. [Google Scholar] [CrossRef] [Scilit]
- Grant, D.; Hayward, V. Controller for a high strain shape memory alloy actuator: Quenching of limit cycles. In Proceedings of the 1997 IEEE International Conference on Robotics and Automation (ICRA), Albuquerque, NM, USA, 20–25 April 1997; Volume 1, pp. 254–259. [Google Scholar] [CrossRef] [Scilit]
- Rad, N.F.; Yousefi-Koma, A.; Rezaei, H.; Bazrafshani, M.A. Design and fabrication of a gripper actuated by shape memory alloy spring. In Proceedings of the 4th International Conference on Robotics and Mechatronics (ICROM), Tehran, Iran, 26–28 October 2016; pp. 455–458. [Google Scholar] [CrossRef] [Scilit]
- Eggeler, G.; Hornbogen, E.; Yawny, A.; Heckmann, A.; Wagner, M. Structural and functional fatigue of NiTi shape memory alloys. Mater. Sci. Eng. A 2004, 378, 24–33. [Google Scholar] [CrossRef] [Scilit]
- Ramaiah, K.V.; Saikrishna, C.N.; Ranganath, V.R.; Buravalla, V.; Bhaumik, S.K. Fracture of thermally activated NiTi shape memory alloy wires. Mater. Sci. Eng. A 2011, 528, 5502–5510. [Google Scholar] [CrossRef] [Scilit]
- Rodrigue, H.; Wang, W.; Kim, D.-R.; Ahn, S.-H. Curved Shape Memory Alloy-Based Soft Actuators and Application to Soft Gripper. Compos. Struct. 2017, 176, 398–406. [Google Scholar] [CrossRef] [Scilit]
- Dezaki, M.L.; Bodaghi, M.; Serjouei, A.; Afazov, S.; Zolfagharian, A. Adaptive Reversible Composite-Based Shape Memory Alloy Soft Actuators. Sens. Actuators A Phys. 2022, 345, 113779. [Google Scholar] [CrossRef] [Scilit]
- Lu, Y.; Xie, Z.; Wang, J.; Yue, H.; Wu, M.; Liu, Y. A Novel Design of a Parallel Gripper Actuated by a Large-Stroke Shape Memory Alloy Actuator. Int. J. Mech. Sci. 2019, 159, 74–80. [Google Scholar] [CrossRef] [Scilit]
- Schmelter, T.; Bade, L.; Kuhlenkötter, B. A Two-Finger Gripper Actuated by Shape Memory Alloy for Applications in Automation Technology with Minimized Installation Space. Actuators 2024, 13, 425. [Google Scholar] [CrossRef] [Scilit]
- Lagoudas, D.C. (Ed.) Shape Memory Alloys: Modeling and Engineering Applications; Springer: New York, NY, USA, 2008. [Google Scholar] [CrossRef] [Scilit]
- Liang, C.; Rogers, C.A. One-dimensional thermo-mechanical constitutive relations for shape memory materials. J. Intell. Mater. Syst. Struct. 1997, 8, 285–302. [Google Scholar] [CrossRef] [Scilit]
- Ge, J.Z.; Chang, L.; Perez-Arancibia, N.O. Preisach-Model-Based Position Control of a Shape-Memory Alloy Linear Actuator in the Presence of Time-Varying Stress. Mechatronics 2021, 73, 102452. [Google Scholar] [CrossRef] [Scilit]
- Curcio, E.M.; Sgambitterra, E.; Lamuta, C.; Maletta, C.; Niccoli, F. Finite state machine-based modeling of shape memory alloy actuators: A multi-physics approach for predicting thermo-mechanical behavior and hysteresis. Sens. Actuators A Phys. 2025, 394, 116990. [Google Scholar] [CrossRef] [Scilit]
- Taylor, F.; Au, C. Forced-Air Cooling of Shape-Memory Alloy Actuators for a Prosthetic Hand. J. Comput. Inf. Sci. Eng. 2016, 16, 041004. [Google Scholar] [CrossRef] [Scilit]
- Liu, R.; Zhang, S.; Baba, Y.; Sawada, H. A Novel Cooling Design for an Agonistic–Antagonistic SMA Tendon-Driven Actuator. Actuators 2023, 12, 415. [Google Scholar] [CrossRef] [Scilit]
- Zhang, Q.; Xu, L.; Chen, H.; Li, Z.; Huang, L.; Yi, S. Research on a Novel Shape-Memory Alloy Artificial Muscle with Active and Passive Heat Dissipation. Actuators 2025, 14, 248. [Google Scholar] [CrossRef] [Scilit]
- Rodinò, S.; Caroleo, G.; Sgambitterra, E.; Bruno, F.; Muzzupappa, M.; Maletta, C. A multiphysics dynamic model for shape memory alloy actuators. Sens. Actuators A Phys. 2023, 362, 114602. [Google Scholar] [CrossRef] [Scilit]
- Romančík, J. Návrh Tvarovo-Pamäťového Koncového SMA Efektora na báze Nitinol Materiálu pre Komerčné Robotické Aplikácie. Ph.D. Thesis, Technical University of Košice, Faculty of Mechanical Engineering, Košice, Slovakia, 2026. [Google Scholar]
- Zhang, X.; Kow, J.; Jones, D.; de Boer, G.; Ghanbari, A.; Serjouei, A.; Culmer, P.; Alazmani, A. Adjustable Compliance Soft Sensor via an Elastically Inflatable Fluidic Dome. Sensors 2021, 21, 1970. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Aldosary, G.; Belec, J.; Foottit, C.; Vandervoort, E. Dosimetric considerations for moldable silicone composites used in radiotherapy applications. J. Appl. Clin. Med. Phys. 2022, 23, e13605. [Google Scholar] [CrossRef] [Scilit]
- Lee, T.-I.; Kim, M.S.; Kim, T.-S. Contact-free thermal expansion measurement of very soft elastomers using digital image correlation. Polym. Test. 2016, 51, 181–189. [Google Scholar] [CrossRef] [Scilit]
- Dassault Systèmes SolidWorks Corp. Hyperelastic Ogden Model. SOLIDWORKS Design Help. 2026. Available online: https://help.solidworks.com/2026/english/SolidWorks/cworks/c_Hyperelastic_Ogden_Model.htm (accessed on 29 July 2026).
- Yap, Y.L.; Toh, W.; Koneru, R.; Chua, Z.Y.; Lin, K.; Yeoh, K.M.; Lim, C.M.; Lee, J.S.; Plemping, N.A.; Lin, R.; et al. Finite element analysis of 3D-Printed Acrylonitrile Styrene Acrylate (ASA) with ultrasonic material characterization. Int. J. Comput. Mater. Sci. Eng. 2019, 8, 1950002. [Google Scholar] [CrossRef] [Scilit]
- Stratasys Ltd. ASA: FDM Thermoplastic Filament Material Data Sheet. Manufacturer Technical Documentation. 2025. Available online: https://www.stratasys.com/siteassets/materials/materials-catalog/fdm-materials/asa/mds_fdm_asa_0826a.pdf?v=4a575c (accessed on 29 July 2026).
- Bambu Lab. Bambu TPU for AMS Technical Data Sheet. Manufacturer Technical Documentation. 2024. Available online: https://bambulab.com/en/filament/tpu-for-ams (accessed on 29 July 2026).
- Xu, Y.-X.; Juang, J.-Y. Measurement of Nonlinear Poisson’s Ratio of Thermoplastic Polyurethanes under Cyclic Softening Using 2D Digital Image Correlation. Polymers 2021, 13, 1498. [Google Scholar] [CrossRef] [Scilit]
- Bacak, S. Simulation and Optimization of the Thermal Performance of Polymer Composite Materials Produced by 3D Printing. Suleyman Demirel Univ. J. Nat. Appl. Sci. 2025, 29, 493–501. [Google Scholar] [CrossRef] [Scilit]



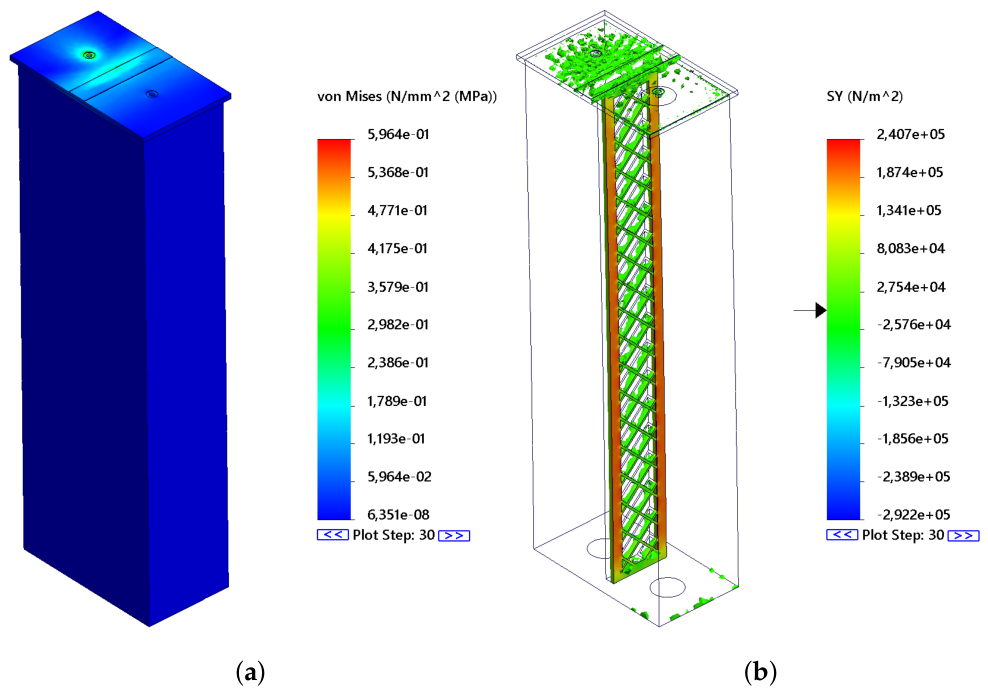


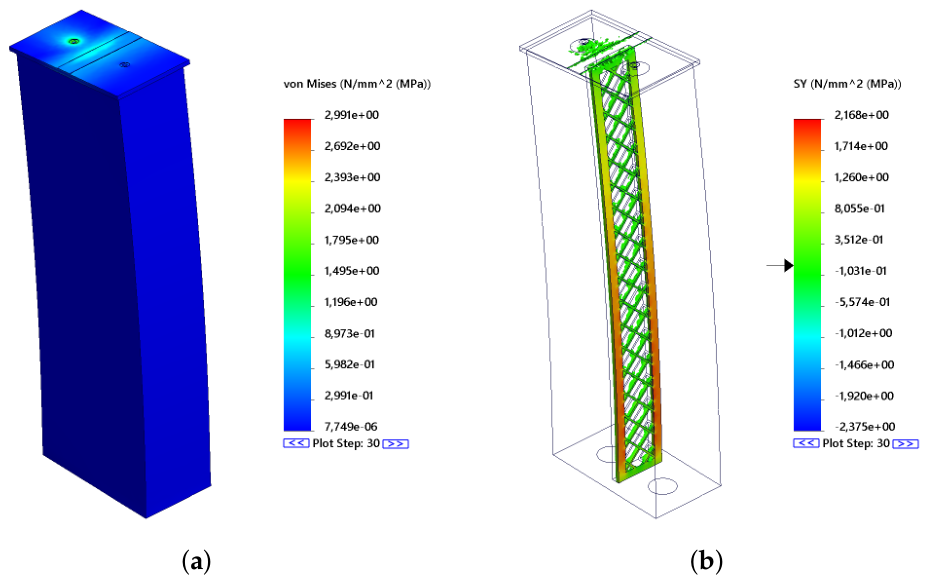


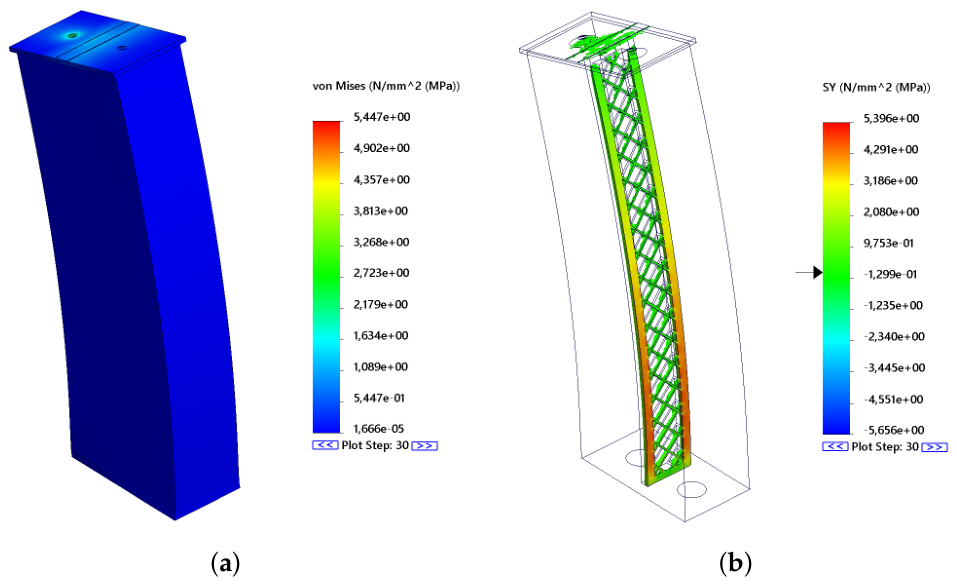
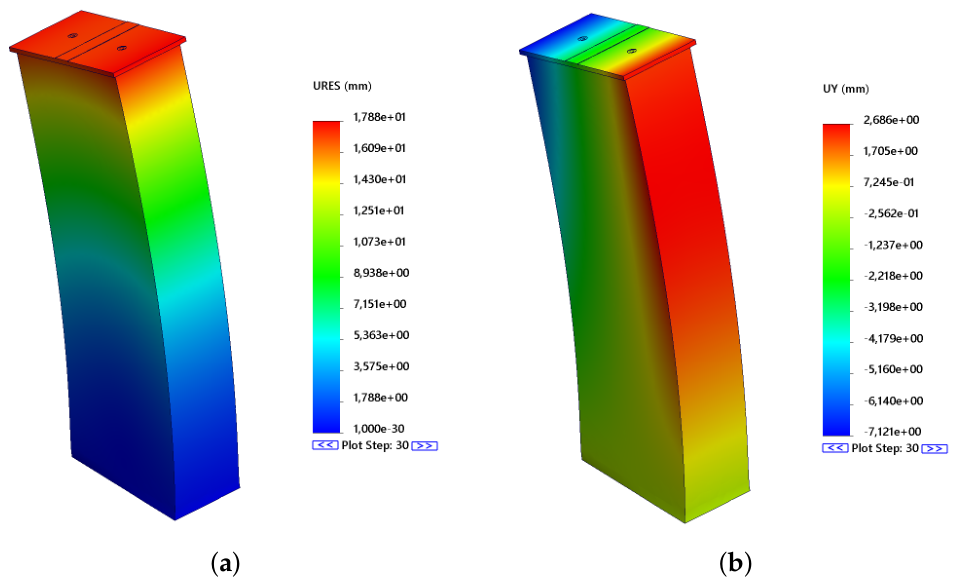


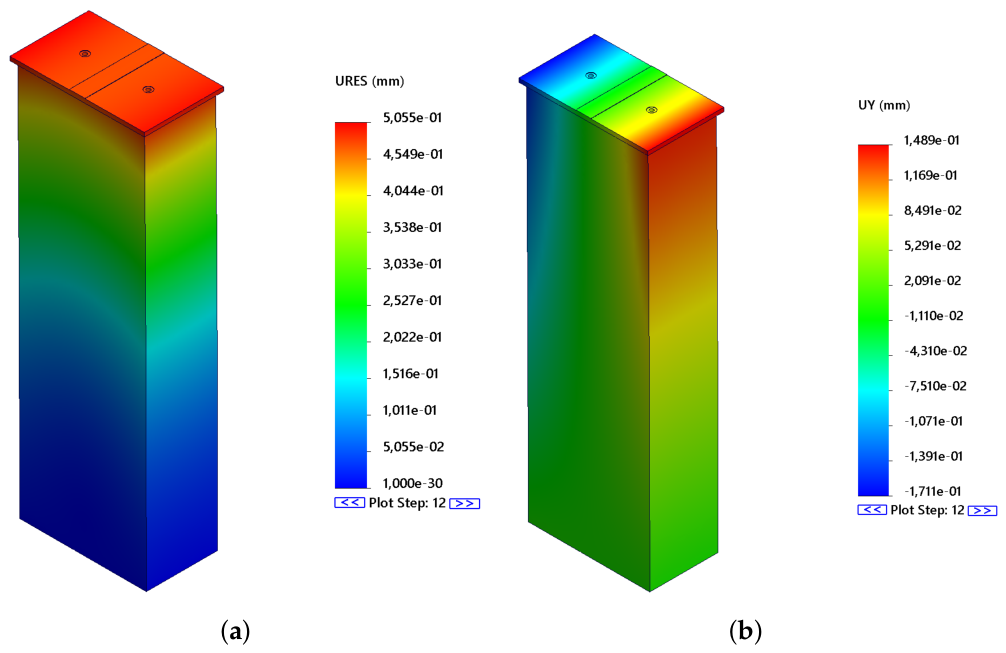
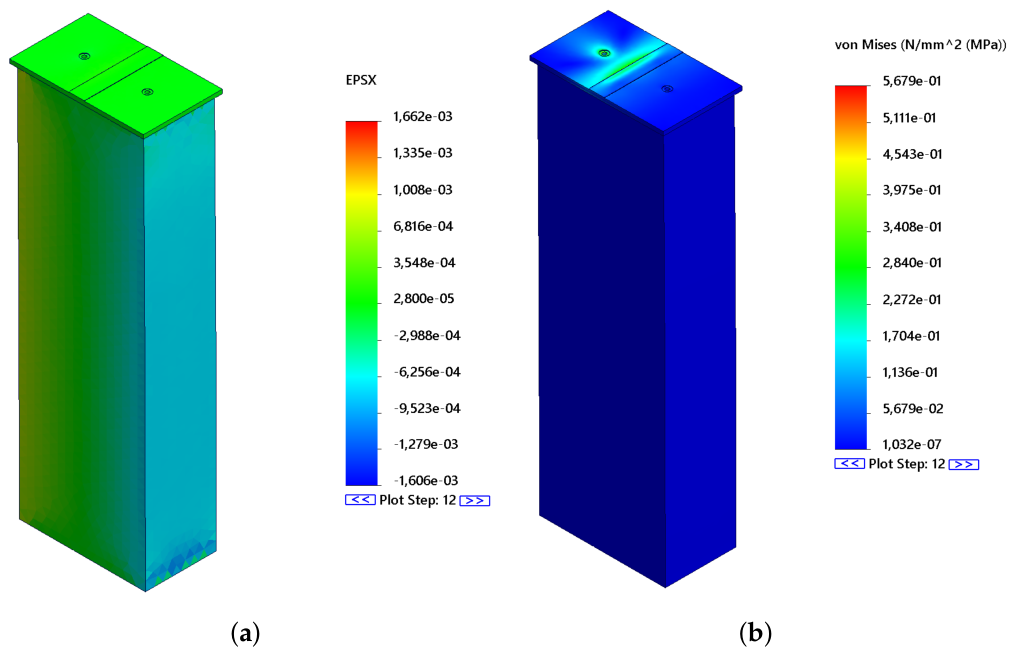

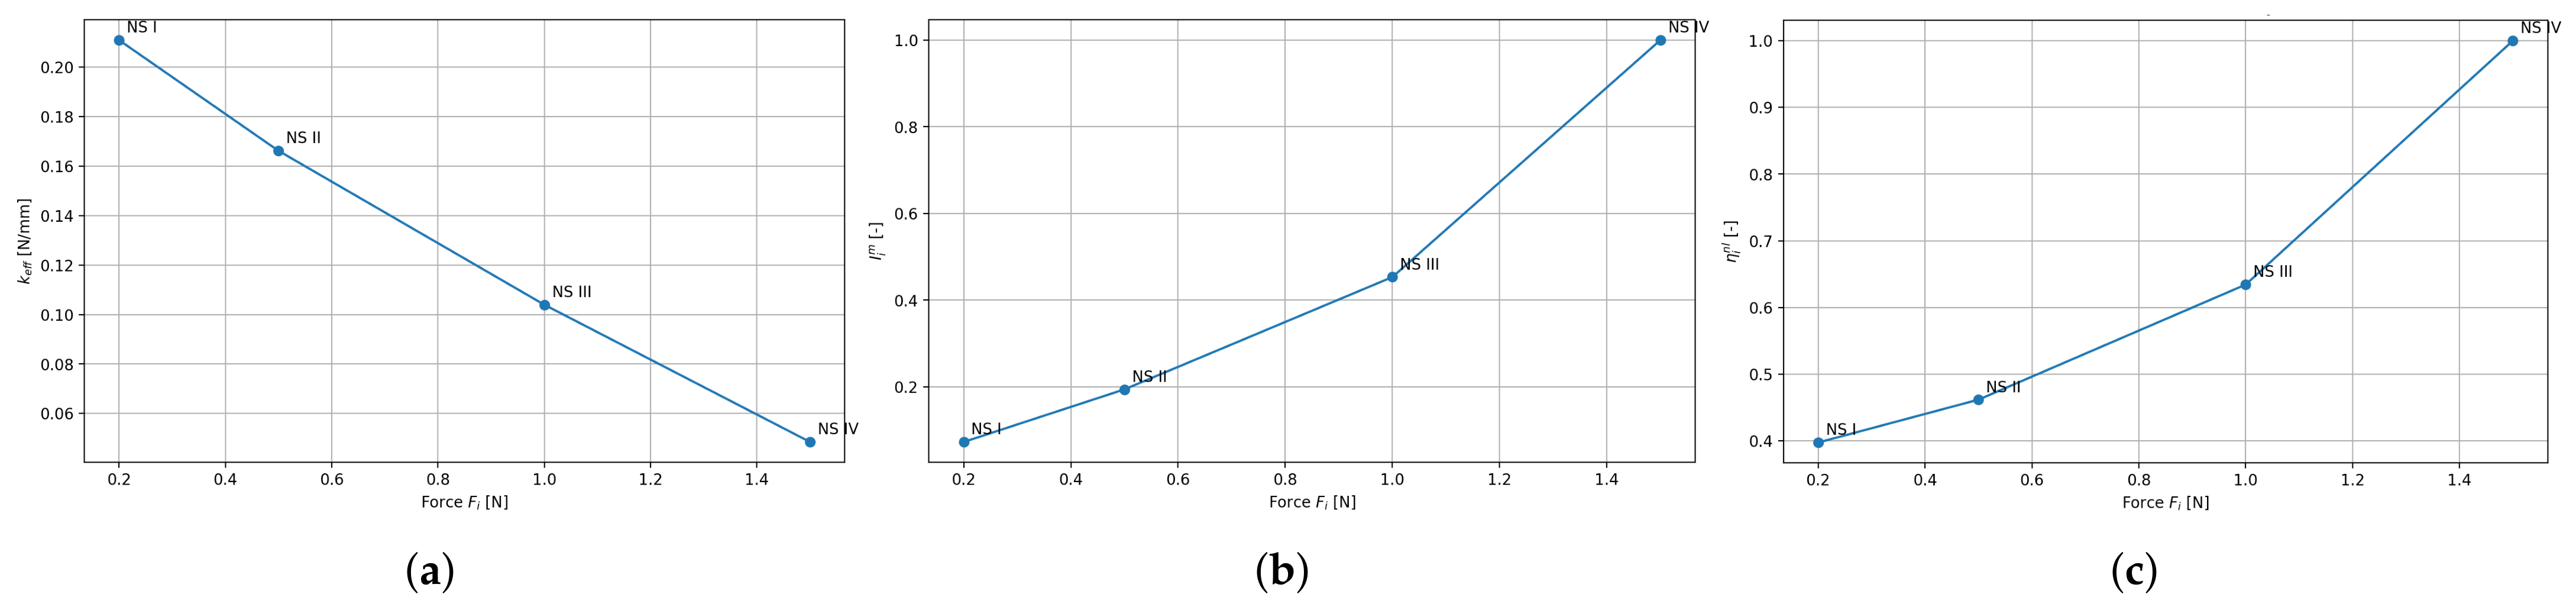
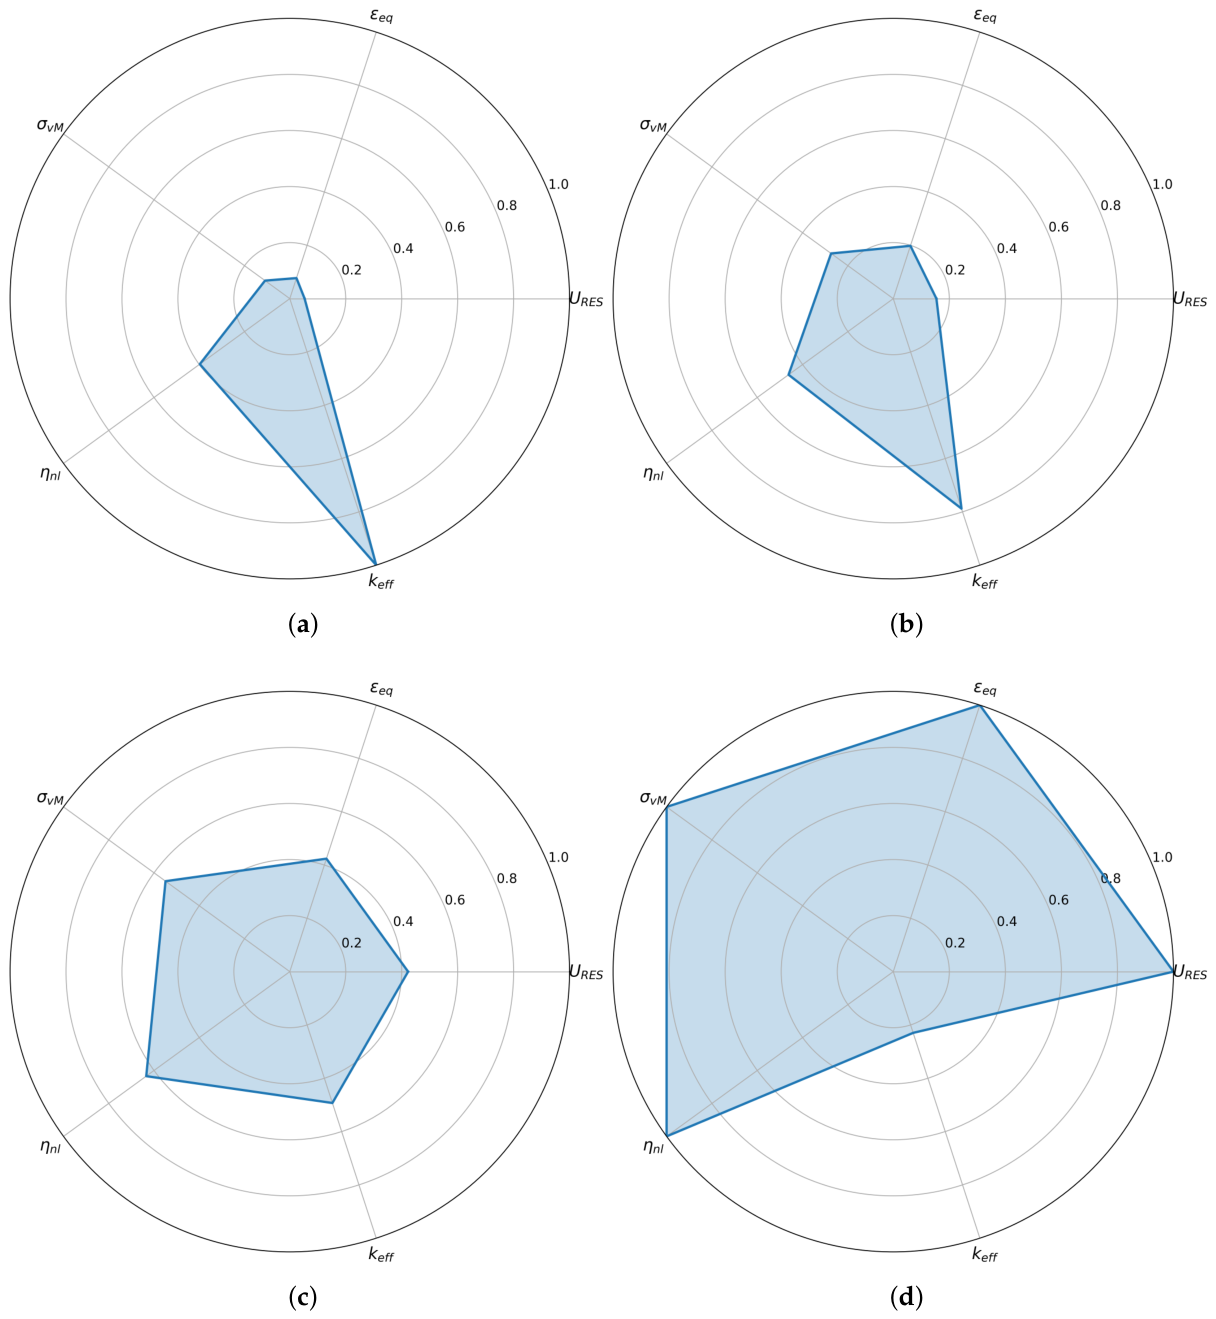
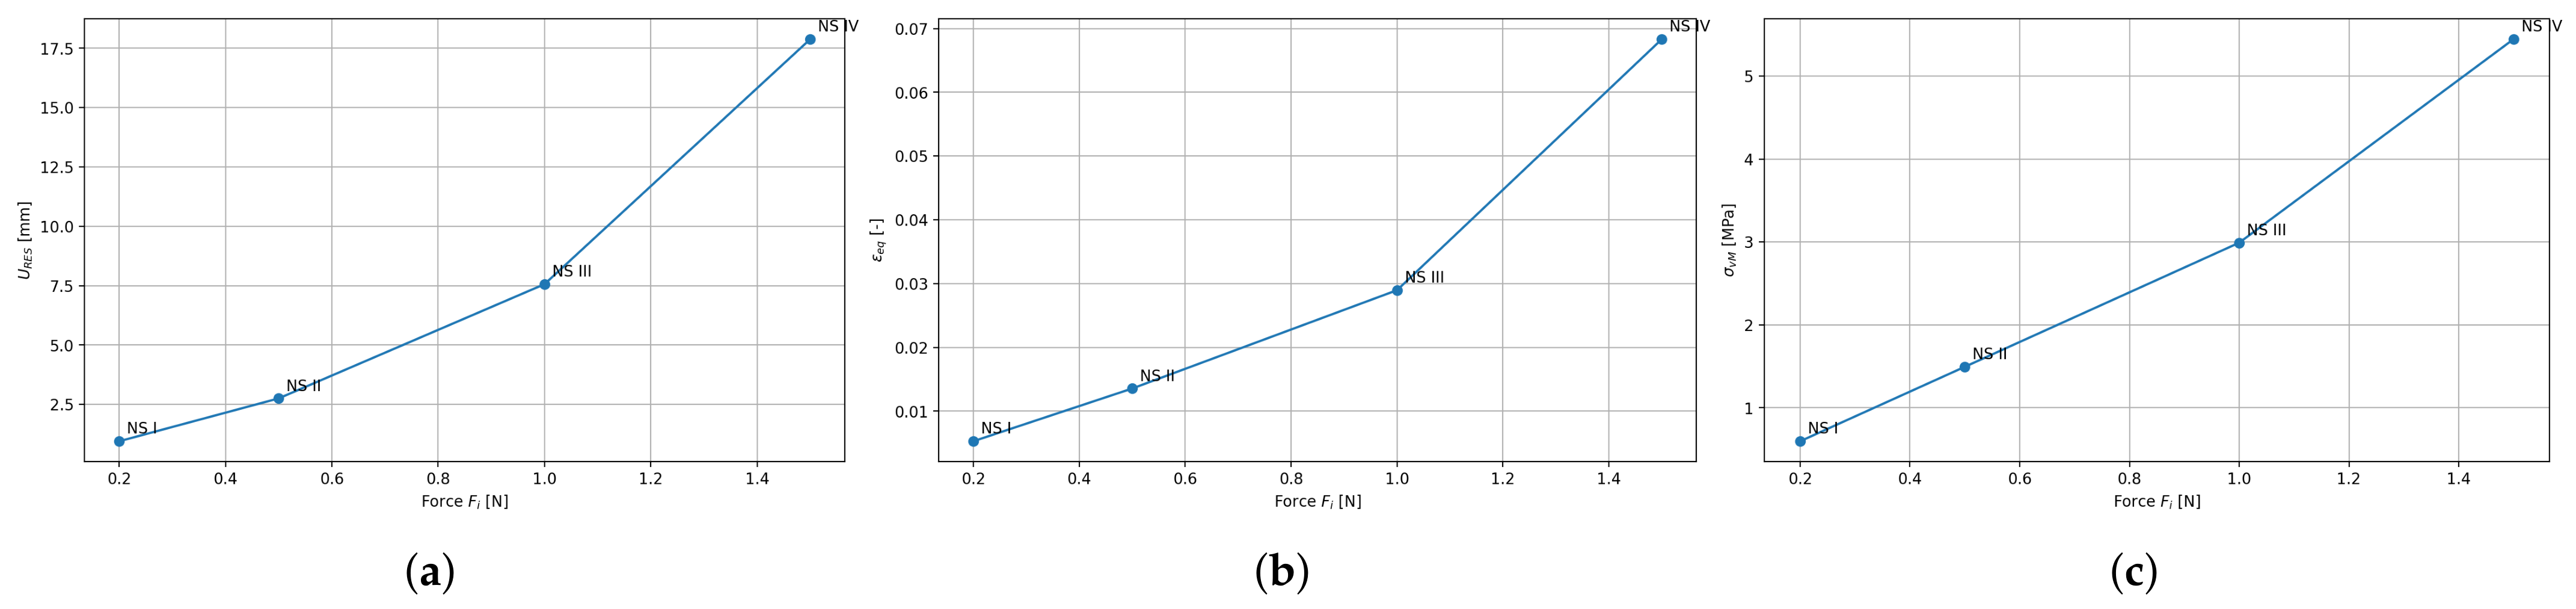
| Study Type | [MPa] | [mm] | [-] | [mm] |
|---|---|---|---|---|
| Nonlinear study I * | 0.596 | 0.948 | −0.905 | |
| Nonlinear study II * | 1.494 | 2.753 | −2.651 | |
| Nonlinear study III * | 2.991 | 7.562 | −7.373 | |
| Nonlinear study IV * | 5.447 | 17.88 | −17.67 |
| Quantity | Experiment | FEA NS III | Difference |
|---|---|---|---|
| Mean absolute bending angle [deg] | 54.18 | 9.83 | 44.35 (81.86%) |
| Response Descriptor | mm | mm | Relative Change |
|---|---|---|---|
| Maximum resultant displacement [mm] | 0.9480 | 0.5055 | |
| Secant stiffness [N/mm] | 0.21097 | 0.39565 | |
| Maximum absolute out-of-plane displacement [mm] | 0.3305 | 0.1711 | |
| Relative out-of-plane displacement [-] | 0.3486 | 0.3385 | |
| Maximum von Mises stress [MPa] | 0.5960 | 0.5679 |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Prada, E.; Romančík, J.; Sincak, P.J.; Miková, Ľ.; Varga, M.; Kelemen, M. Morphology-Guided Nonlinear Structural Evaluation of a Hybrid Bio-Inspired Soft Robotic Actuator. Actuators 2026, 15, 494. https://doi.org/10.3390/act15090494
Prada E, Romančík J, Sincak PJ, Miková Ľ, Varga M, Kelemen M. Morphology-Guided Nonlinear Structural Evaluation of a Hybrid Bio-Inspired Soft Robotic Actuator. Actuators. 2026; 15(9):494. https://doi.org/10.3390/act15090494
Chicago/Turabian StylePrada, Erik, Jaroslav Romančík, Peter Jan Sincak, Ľubica Miková, Martin Varga, and Michal Kelemen. 2026. "Morphology-Guided Nonlinear Structural Evaluation of a Hybrid Bio-Inspired Soft Robotic Actuator" Actuators 15, no. 9: 494. https://doi.org/10.3390/act15090494
APA StylePrada, E., Romančík, J., Sincak, P. J., Miková, Ľ., Varga, M., & Kelemen, M. (2026). Morphology-Guided Nonlinear Structural Evaluation of a Hybrid Bio-Inspired Soft Robotic Actuator. Actuators, 15(9), 494. https://doi.org/10.3390/act15090494