Design of Dual-Motor Drive Composite Control Strategy Based on Iterative Learning Feedforward Control and Super-Twisting Sliding Mode Observer

Abstract
1. Introduction
- (1)
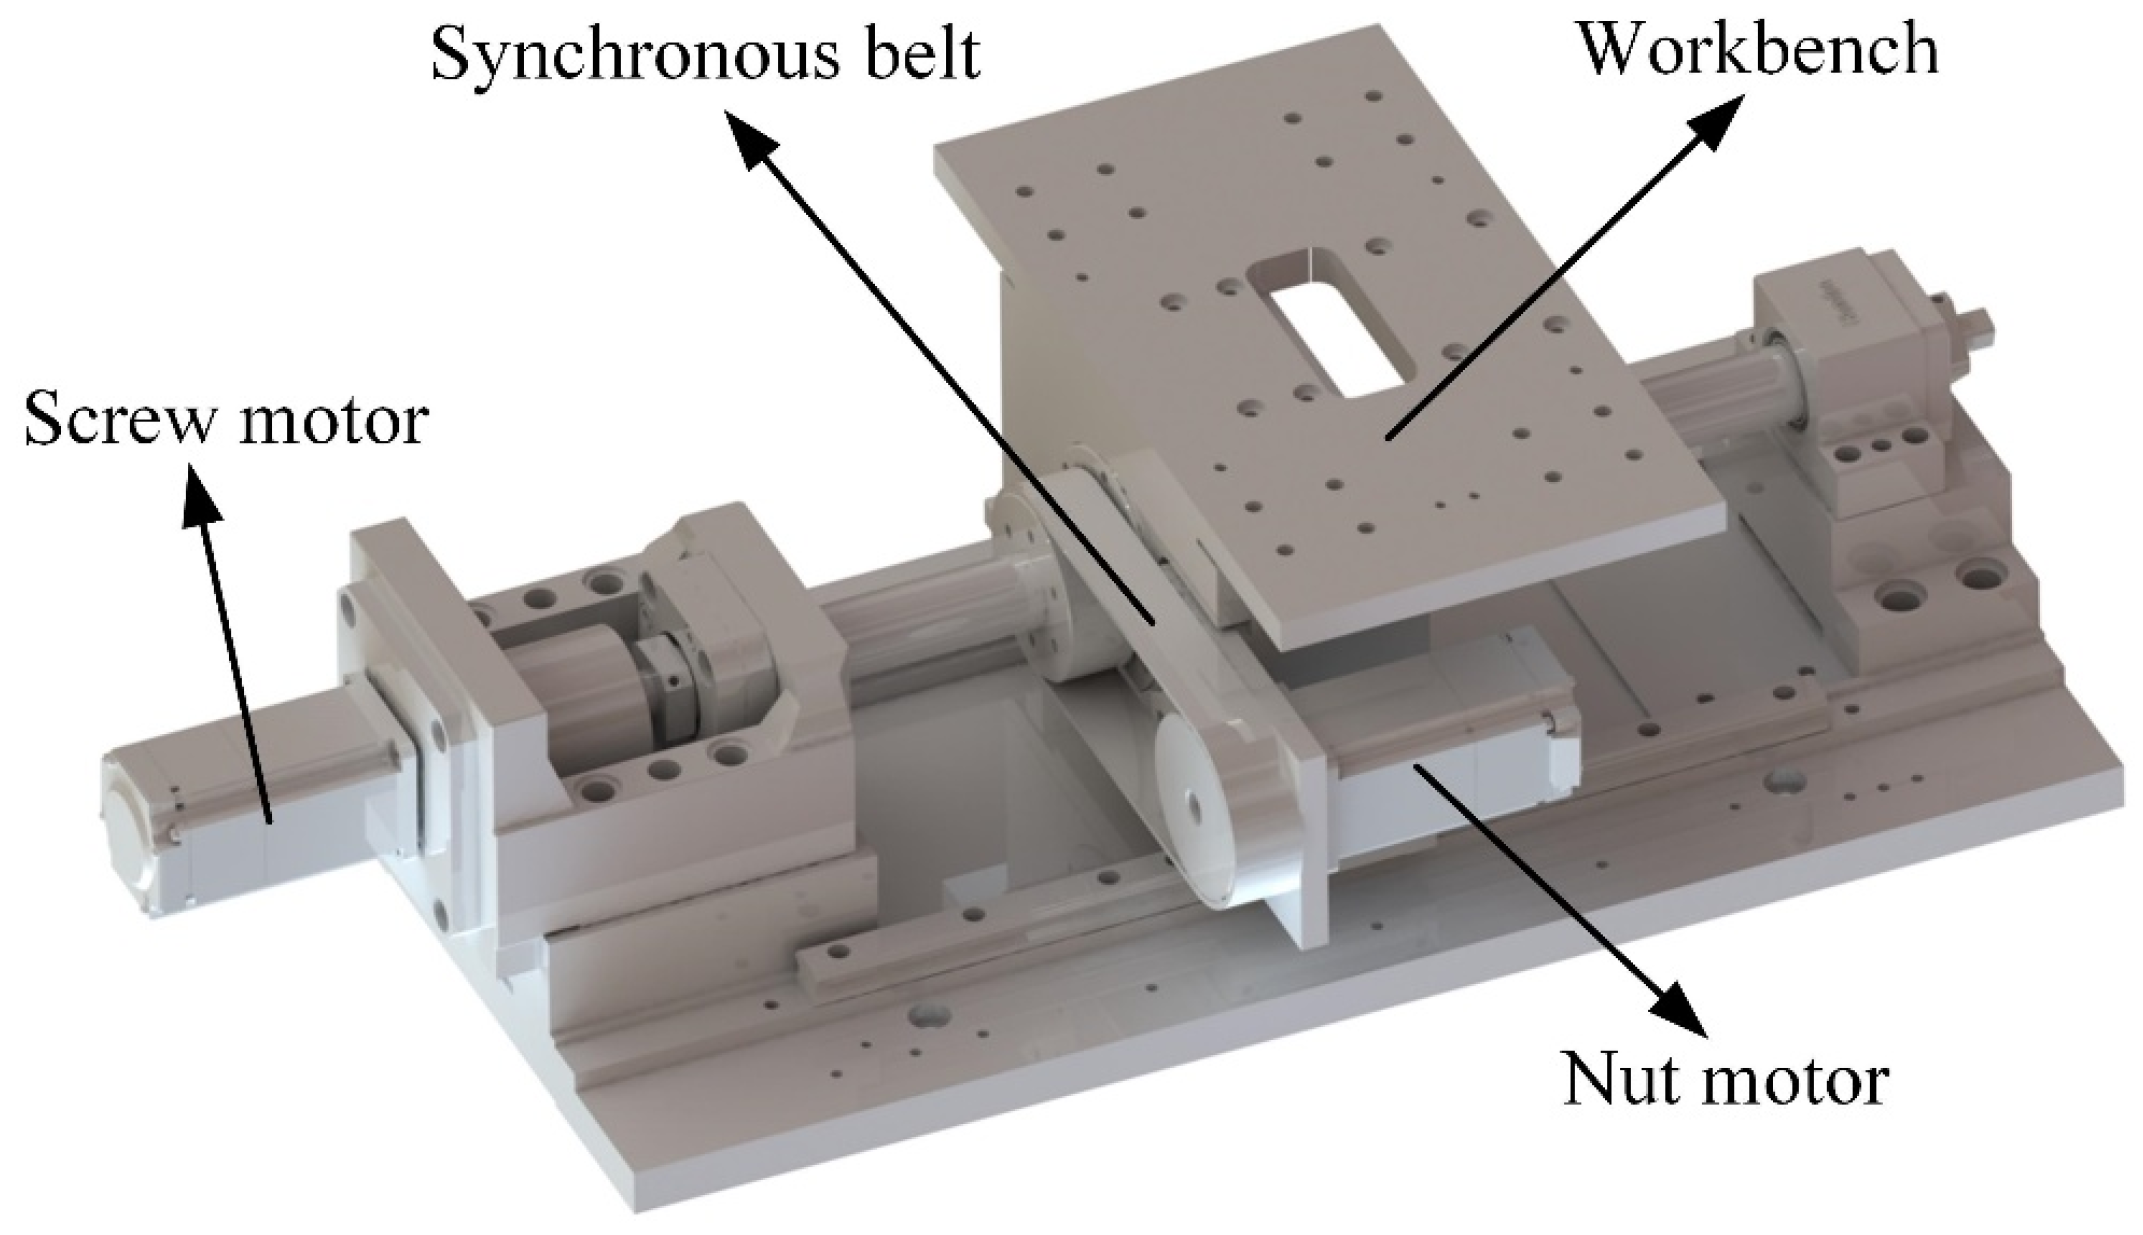
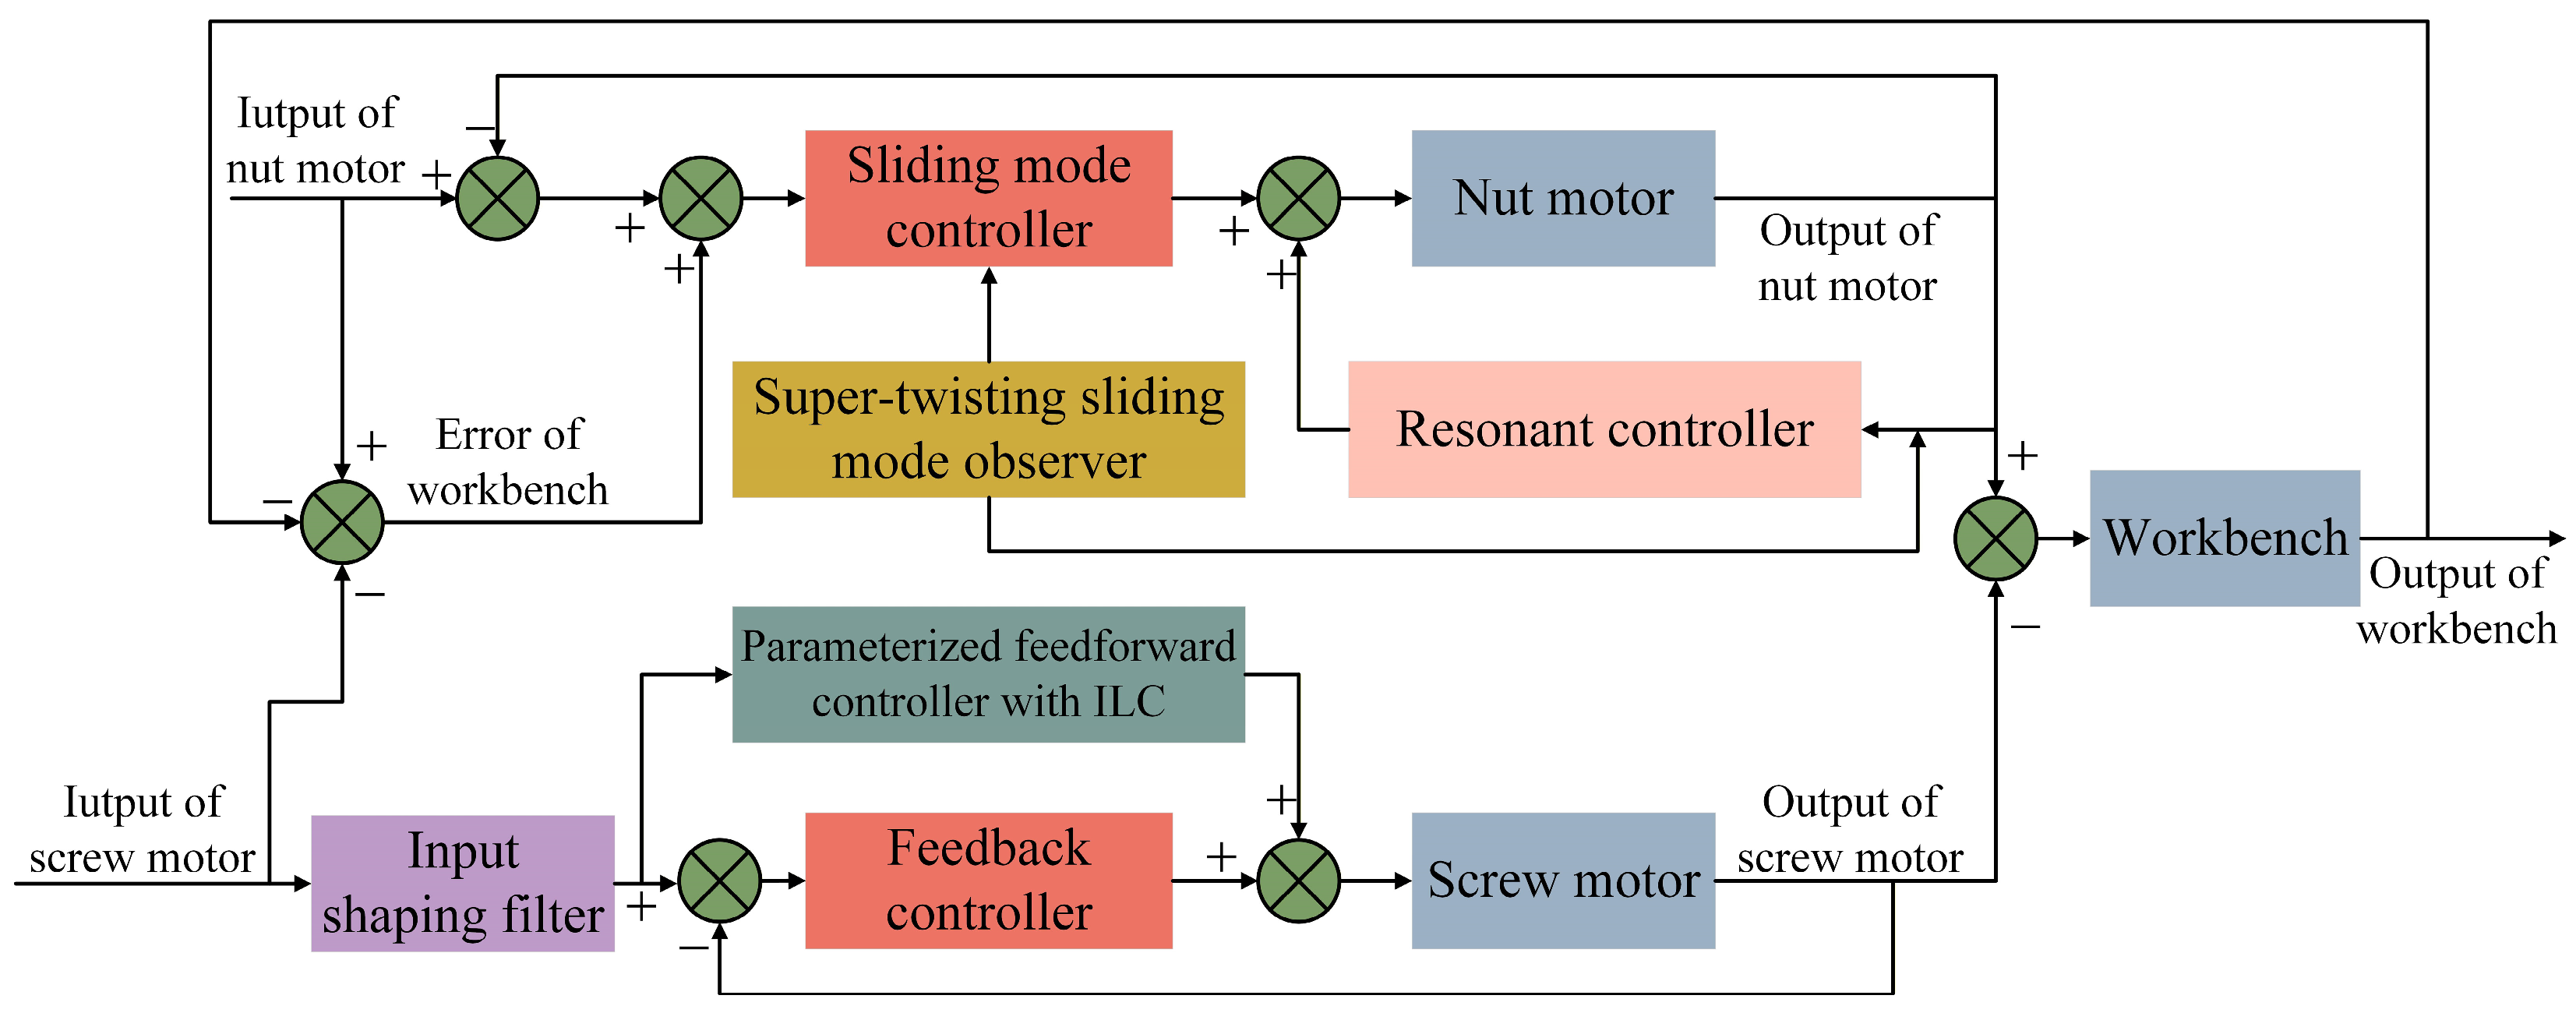
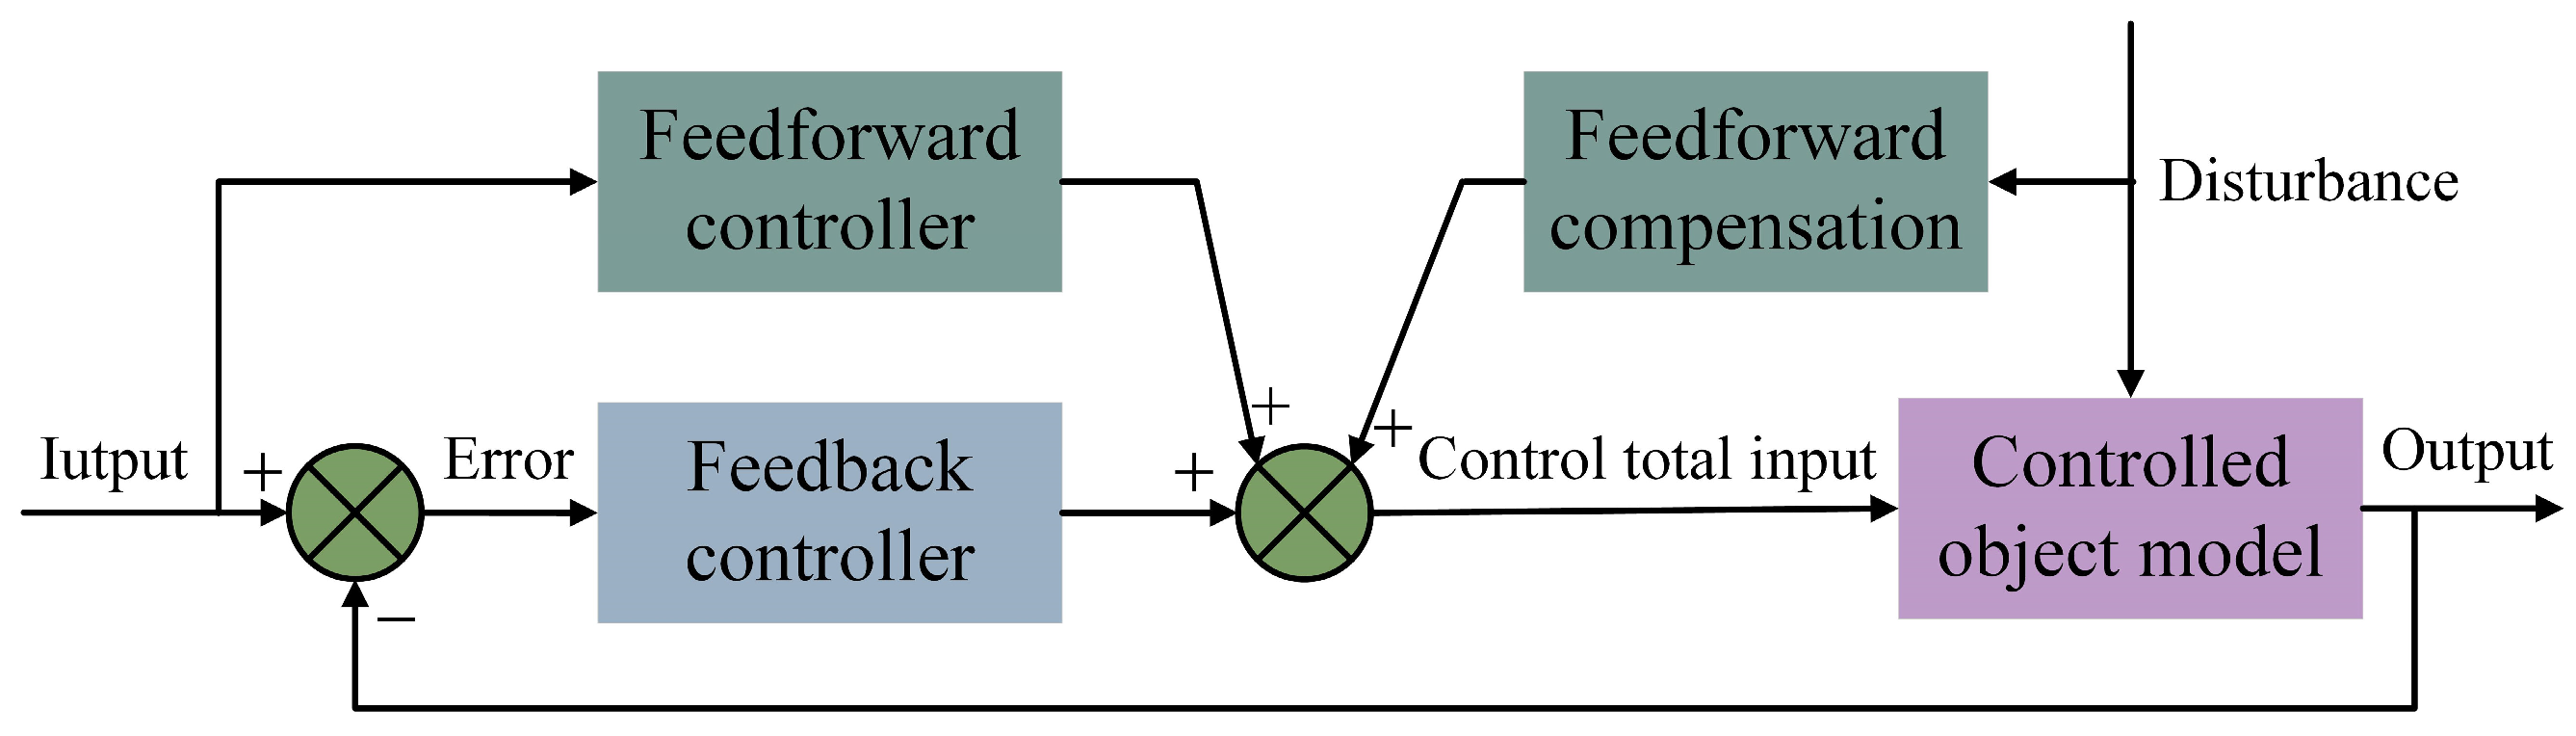
- A disturbance-oriented composite control framework is proposed for the differential dual-drive servo system. Unlike conventional dual-motor schemes that apply similar control laws to both motors, the proposed method assigns different disturbance-suppression tasks to two actuators. The nut motor is responsible for robust real-time suppression of non-periodic disturbances, and the screw motor is responsible for iterative compensation of repetitive periodic disturbances.
- (2)
- A super-twisting sliding mode observer is designed for the nut motor to suppress the non-periodic total disturbance, and an SMC based on the improved new reaching law is proposed. Through Lyapunov theory, it is proven that the control system is asymptotically stable, the error is bounded and the convergence is zero.
- (3)
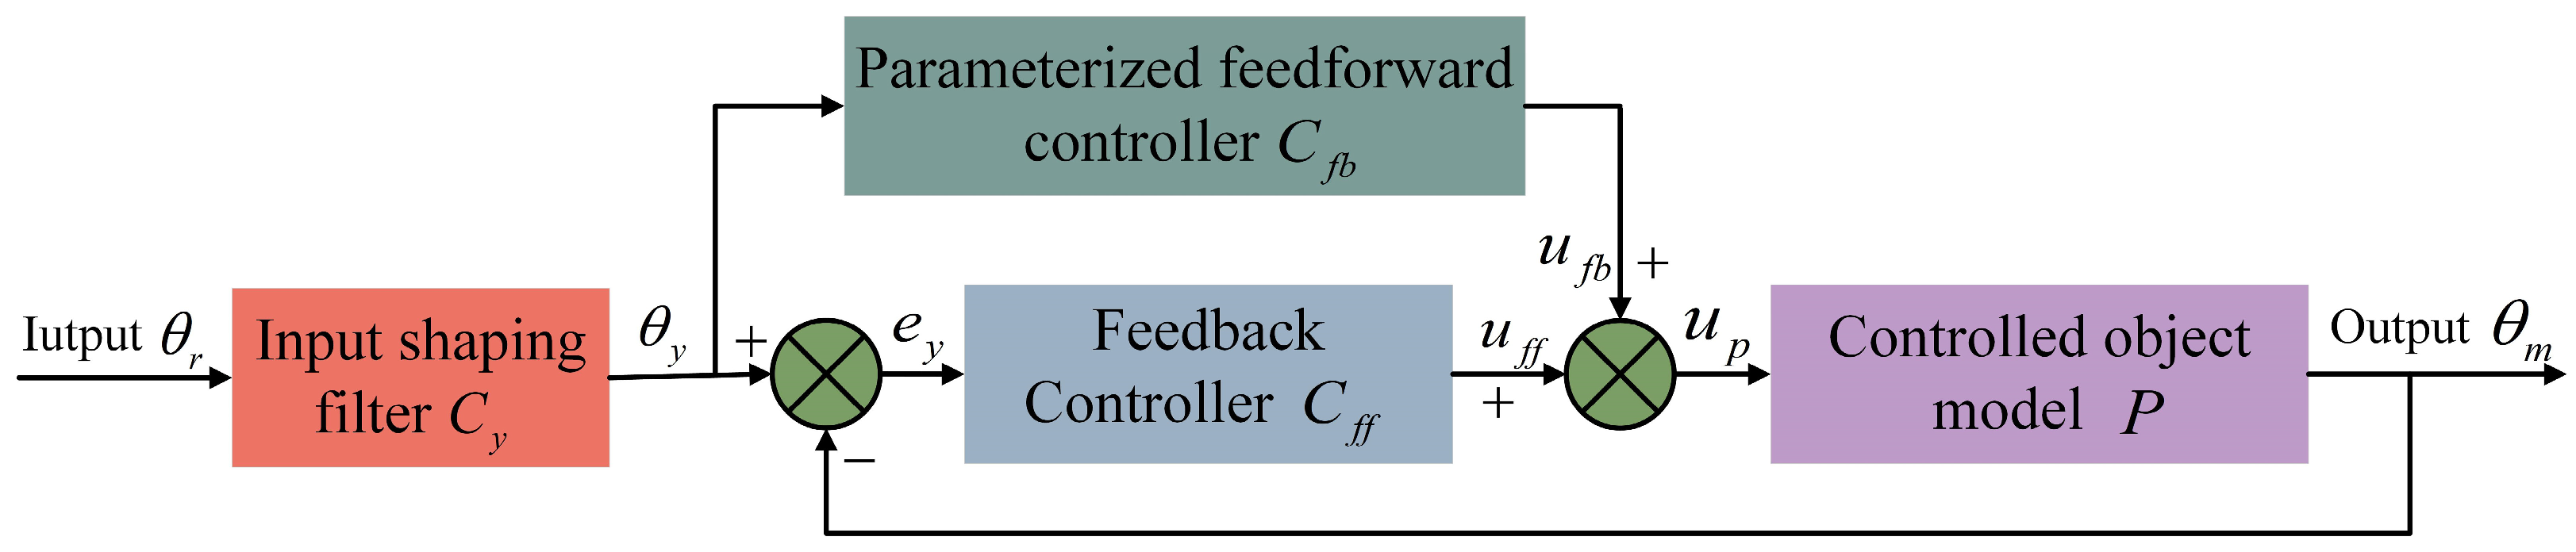
- A parametric feedforward controller based on an input-shaping filter is designed for the screw motor. The parameters are optimized iteratively in the process of iterative learning by a data-driven method.
2. Differential Dual-Drive Servo System Model and Problem Statement
- (1)
- The magnetic core is unsaturated, that is, the magnetic circuit saturation is ignored;
- (2)
- The three-phase windings are symmetrically distributed, and the axes of each winding are 120 degrees apart in space;
- (3)
- The core permeability is infinite, ignoring the eddy current loss and hysteresis loss of the stator and rotor core;
- (4)
- Constant winding resistance and inductance;
- (5)
- The end effect and alveolar effect are ignored.
3. Design of Sliding Mode Controller Based on Super-Twisting Sliding Mode Observer
3.1. Design of Sliding Mode Controller Based on New Reaching Law
3.2. Design of Super-Twisting Sliding Mode Observer for Non-Periodic Total Disturbances
3.3. Design of Resonant Controller for Medium- and High-Frequency Periodic Disturbances
4. Design of Feedforward Controller Based on Iterative Learning
4.1. Parameterized Feedforward Controller Based on Input-Shaping Filter
4.2. Iterative Parameter Update Based on a Data-Driven Method
4.3. Algorithm Procedure
| Algorithm 1. Optimal iterative feedforward parameter algorithm |
|
5. Experimental Verification
5.1. Experimental Equipment and Parameter Setting
5.2. Experimental Results and Discussion
6. Conclusions
Author Contributions
Funding
Institutional Review Board Statement
Informed Consent Statement
Data Availability Statement
Acknowledgments
Conflicts of Interest
Abbreviations
| SMC | Sliding mode control |
| ILC | Iterative Learning Control |
| PMSM | Permanent magnet synchronous motor |
| AFCC | Adaptive friction compensation controller |
| GESO-SMC | Sliding mode controller based on generalized extended state observer |
| STSMO-SMC | Sliding mode controller based on super-twisting sliding mode observer |
| ILFFC | Feedforward controller based on iterative learning |
References
- Qian, L.; Sun, L.; Wang, K.; Tong, M. Fusion of Position Estimation Techniques for a Swing Servo by a Permanent-Magnet Synchronous Machine. IEEE Trans. Ind. Electron. 2023, 70, 6551–6562. [Google Scholar] [CrossRef] [Scilit]
- Sun, L.; Li, X.; Chen, L.; Shi, H.; Jiang, Z. Dual-Motor Coordination for High-Quality Servo With Transmission Backlash. IEEE Trans. Ind. Electron. 2023, 70, 1182–1196. [Google Scholar] [CrossRef] [Scilit]
- Wang, T.; Zhang, Q.; Fang, J.; Lai, Z.; Feng, R.; Wei, J. Active fault-tolerant control for the dual-valve hydraulic system with unknown dead-zone. ISA Trans. 2023, 145, 399–411. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Yao, X.; Zhang, L.; Cui, Y. Adaptive Refined Disturbance Observer-Based Velocity-Tracking Control for Gimbal Servo System With Multiple Disturbances. IEEE Trans. Syst. Man Cybern. Syst. 2024, 54, 7170–7181. [Google Scholar] [CrossRef] [Scilit]
- Cui, Y.; Zhu, Y.; Liu, J.; Wang, C.; Zhao, L. Analysis, Estimation, and Rejection of Multi-Frequency Unknown Disturbances in CMG Gimbal Servo Systems. IEEE Trans. Circuits Syst. II-Express Briefs 2024, 71, 4501–4505. [Google Scholar] [CrossRef] [Scilit]
- Tang, C.; Fan, Y.; Yang, C.; Cheng, M.; Lee, C.H.T. Friction Identification and Compensation for SPMSM Using Robust Adaptive Observer. IEEE J. Emerg. Sel. Top. Power Electron. 2024, 12, 4754–4766. [Google Scholar] [CrossRef] [Scilit]
- Niu, S.; Wang, J.; Zhao, J.; Shen, W. Neural network-based finite-time command-filtered adaptive backstepping control of electro-hydraulic servo system with a three-stage valve. ISA Trans. 2024, 144, 419–435. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Li, J.; Li, Y.; Li, X.; Mao, D.; Zhang, B. Adaptive Disturbance Suppression Method for Servo Systems Based on State Equalizer. Sensors 2024, 24, 4418. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Junejo, A.K.; Xu, W.; Mu, C.; Ismail, M.M.; Liu, Y. Adaptive Speed Control of PMSM Drive System Based a New Sliding-Mode Reaching Law. IEEE Trans. Power Electron. 2020, 35, 12110–12121. [Google Scholar] [CrossRef] [Scilit]
- Hou, Q.; Ding, S.; Yu, X. Composite Super-Twisting Sliding Mode Control Design for PMSM Speed Regulation Problem Based on a Novel Disturbance Observer. IEEE Trans. Energy Convers. 2021, 36, 2591–2599. [Google Scholar] [CrossRef] [Scilit]
- Shi, S.; Dai, L.; Min, H.; Yang, J.; Li, S. Prescribed-Time Nonsingular Terminal Sliding Mode Control and Its Application in PMSM Servo Systems. IEEE Trans. Ind. Electron. 2024, 72, 3072–3081. [Google Scholar] [CrossRef] [Scilit]
- Zhufu, G.; Wang, S.; Wang, X. Finite time disturbance observer based sliding mode control for PMSM with unknown disturbances. Int. J. Robust Nonlinear Control 2024, 34, 7547–7564. [Google Scholar] [CrossRef] [Scilit]
- Gao, Y.; Shen, G.; Li, X.; Zhu, Z.; Wang, Q. An Improved Nonlinear Extended Disturbance Observer for Sliding Mode Control in Electro-Hydraulic Servo System. IEEE/ASME Trans. Mechatron. 2024, 30, 2155–2164. [Google Scholar] [CrossRef] [Scilit]
- Sun, Y.; Yang, M.; Wang, B.; Chen, Y.; Xu, D. Precise Position Control Based on Resonant Controller and Second-Order Sliding Mode Observer for PMSM-Driven Feed Servo System. IEEE Trans. Transp. Electrif. 2023, 9, 196–209. [Google Scholar] [CrossRef] [Scilit]
- Zhang, C.; Qi, R.; Li, B.; Riaz, S. Experimental validation and analysis of hybrid adaptive iterative learning sliding mode control for PMSM seeker coordinator. Eng. Sci. Technol. Int. J. 2024, 58, 101826. [Google Scholar] [CrossRef] [Scilit]
- Yang, T.; Deng, Y.; Li, H.; Sun, Z.; Cao, H.; Wei, Z. Fast integral terminal sliding mode control with a novel disturbance observer based on iterative learning for speed control of PMSM. ISA Trans. 2023, 134, 460–471. [Google Scholar] [CrossRef] [Scilit]
- Dumanli, A.; Sencer, B. Data-Driven Iterative Trajectory Shaping for Precision Control of Flexible Feed Drives. IEEE-ASME Trans. Mechatron. 2021, 26, 2735–2746. [Google Scholar] [CrossRef] [Scilit]
- Fu, X.; Yang, X.; Zanchetta, P.; Tang, M.; Liu, Y.; Chen, Z. An Adaptive Data-Driven Iterative Feedforward Tuning Approach Based on Fast Recursive Algorithm: With Application to a Linear Motor. IEEE Trans. Ind. Inform. 2023, 19, 6160–6169. [Google Scholar] [CrossRef] [Scilit]
- Huang, M.; Deng, Y.; Li, H.; Wang, J. Torque ripple attenuation of PMSM using improved robust two-degree-of-freedom controller via extended sliding mode parameter observer. ISA Trans. 2022, 129, 558–571. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Zhang, W.; Nan, N.; Yang, Y.; Zhong, W.; Chen, Y. Force ripple compensation in a PMLSM position servo system using periodic adaptive learning control. ISA Trans. 2019, 95, 266–277. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Wang, Z.; Feng, X.; Du, F.; Li, H.; Su, Z. A novel method for smooth low-speed operation of linear feed systems. Precis. Eng. 2019, 60, 215–221. [Google Scholar] [CrossRef] [Scilit]
- Du, F.; Li, P.; Wang, Z.; Yue, M.; Feng, X. Modeling, identification and analysis of a novel two-axis differential micro-feed system. Precis. Eng. 2017, 50, 320–327. [Google Scholar] [CrossRef] [Scilit]
- Liu, Y.C.; Laghrouche, S.; Depernet, D.; N’Diaye, A.; Djerdir, A.; Cirrincione, M. Super-twisting sliding-mode observer-based model reference adaptive speed control for PMSM drives. J. Frankl. Inst. 2023, 360, 985–1004. [Google Scholar]
- Lu, Z.; Feng, X.; Su, Z.; Liu, Y.; Yao, M. Friction Parameters Dynamic Change and Compensation for a Novel Dual-Drive Micro-Feeding System. Actuators 2022, 11, 236. [Google Scholar] [CrossRef] [Scilit]
- Qiong, W.; Zongxia, J.; Jun, W.; Shuting, L.I. Control of Pneumatic Position Servo with LuGre Model-based Friction Compensation. J. Mech. Eng. 2018, 54, 131–138. [Google Scholar] [CrossRef] [Scilit]








| Symbol | Description | Symbol | Description |
|---|---|---|---|
| D-axis and q-axis voltages | D-axis and q-axis currents | ||
| Stator winding resistance | D-axis and q-axis inductances | ||
| Permanent magnet flux linkage | Rotor electrical angular velocity | ||
| Pole pair | Rotor mechanical angular velocity | ||
| Electromagnetic torque | Load torque | ||
| Damping viscosity coefficient | Moment of inertia of the motor | ||
| Torque coefficient | Deviation of the moment of inertia | ||
| Deviation of the torque coefficient | Uncertainty of the damping coefficient | ||
| Non-periodic total disturbances | Periodic total disturbances | ||
| Control quantity of the system | Output of the system | ||
| Sliding surface | Tracking error | ||
| Proportional coefficient | Integral coefficient | ||
| Variable gain coefficient | Control gain | ||
| Exponential decay rate | Integral sliding surface | ||
| Integral constant | Observation error | ||
| Sliding mode control law | Sliding mode control law | ||
| Observer gain | Gain of the resonant controller | ||
| Symbol function | Proportional factors | ||
| Adjustable phase angle term | Parameterized feedforward controller | ||
| Input-shaping filter | Feedback controller | ||
| Desired input trajectory signal | Input trajectory signal after shaping | ||
| Trajectory tracking error | Feedforward control signal | ||
| Feedback control signal | Integrated control signal | ||
| System output trajectory signal | Feedforward controller parameter | ||
| Basis function vector | Parameter variation | ||
| System closed-loop sensitivity function | Transfer relationship from equivalent control input to output | ||
| Sensitivity function | Constraint coefficients of control signal | ||
| Influence matrix of feedforward parameter variations on the tracking error in the next iteration | Influence matrix of feedforward parameter variations on the control input and its increment |
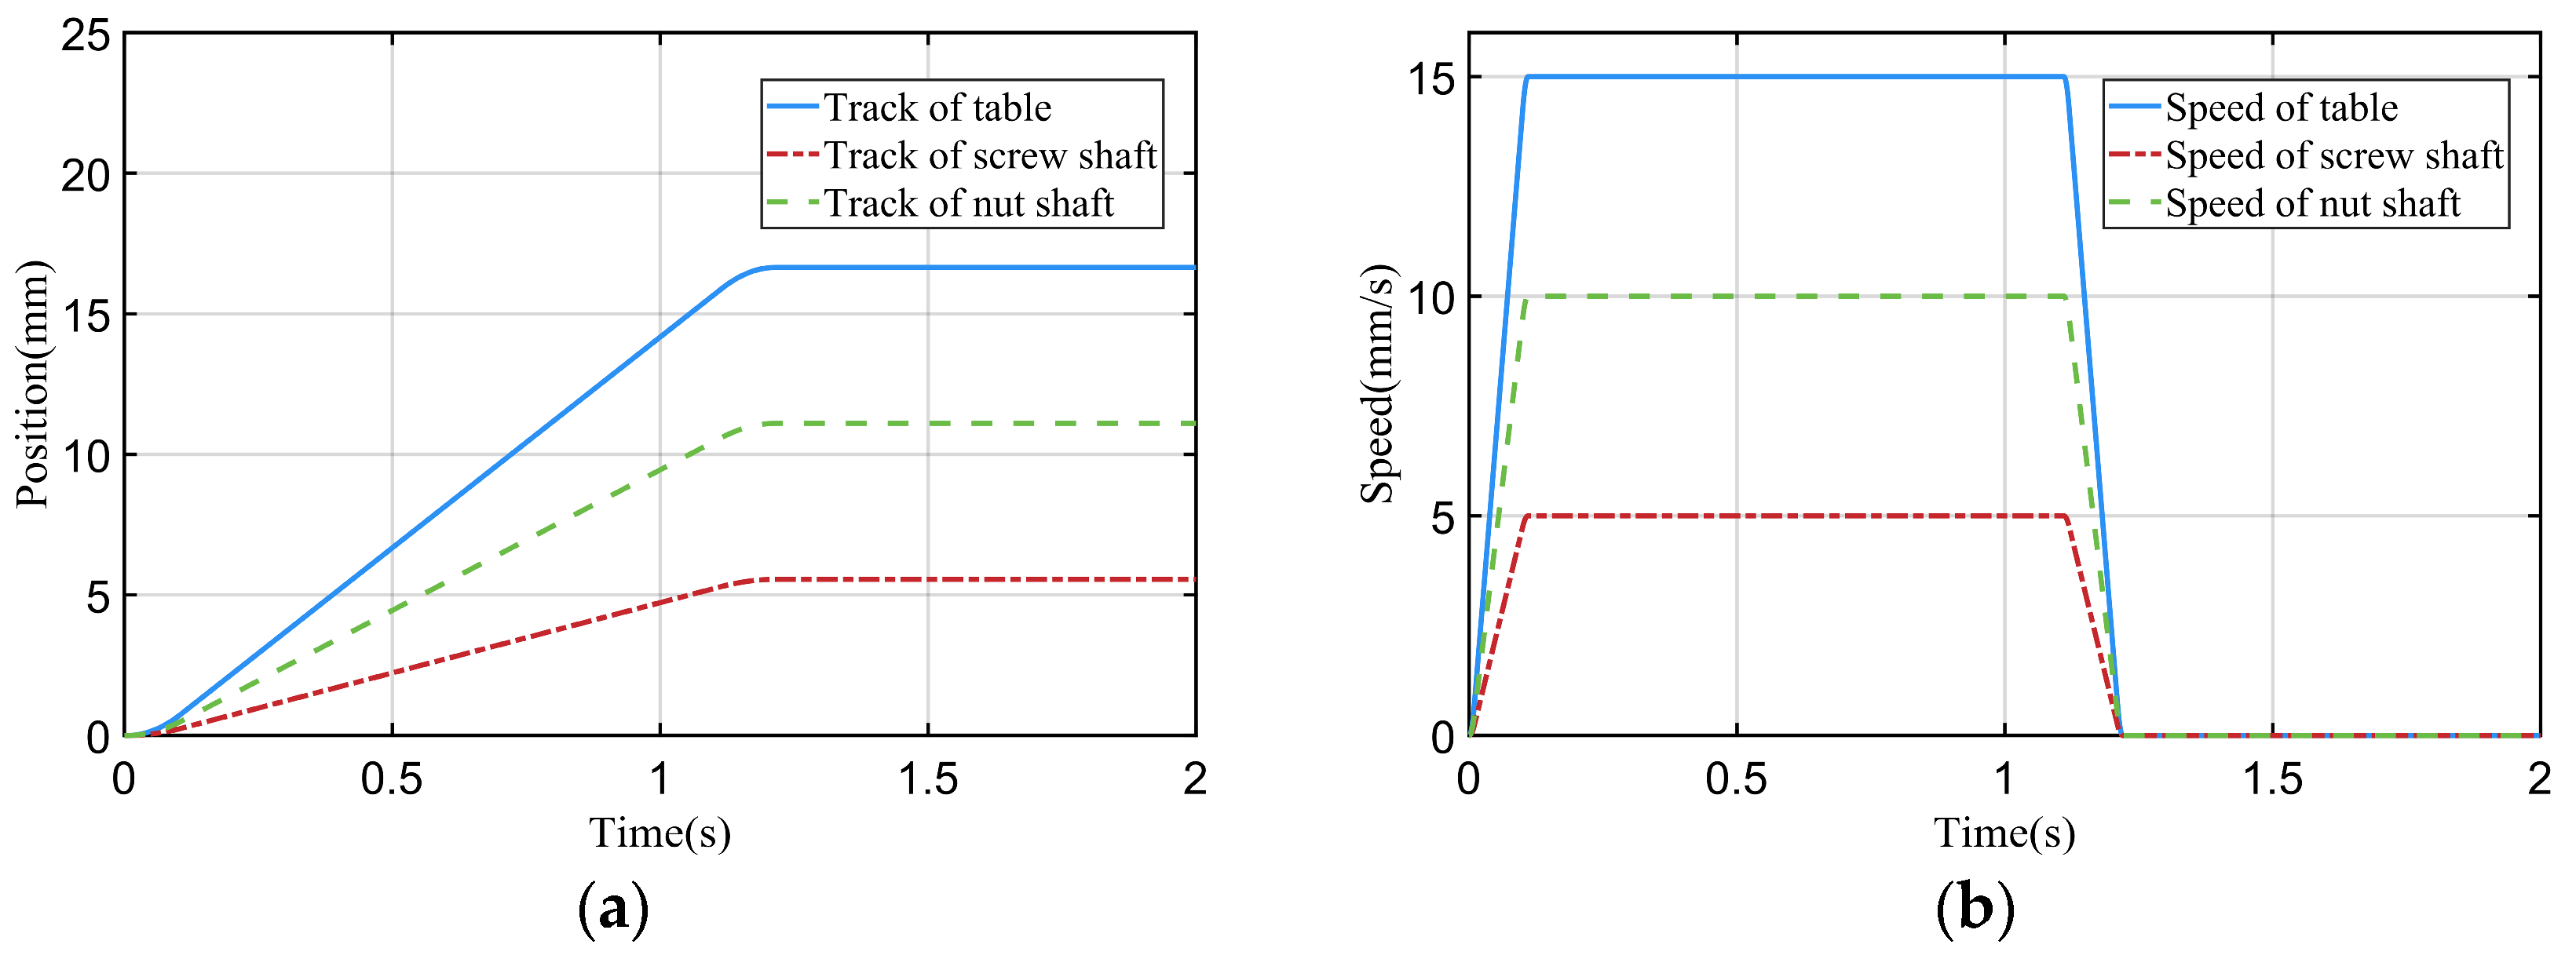
| Parameter | Value | Parameter | Value |
|---|---|---|---|
| Lead of screw | 5 mm | Rated current | 2.1 A |
| Worktable weight | 20 kg | Rotor inertia | 0.58 × 10⁻⁴ kg m2 |
| Transmission efficiency | 0.9 | Number of pole-pairs | 4 |
| Rated power | 400 W | Flux linkage | 0.015 Wb |
| Rated Torque | 1.27 N | Viscous damping coefficient | 0.02 N m s |
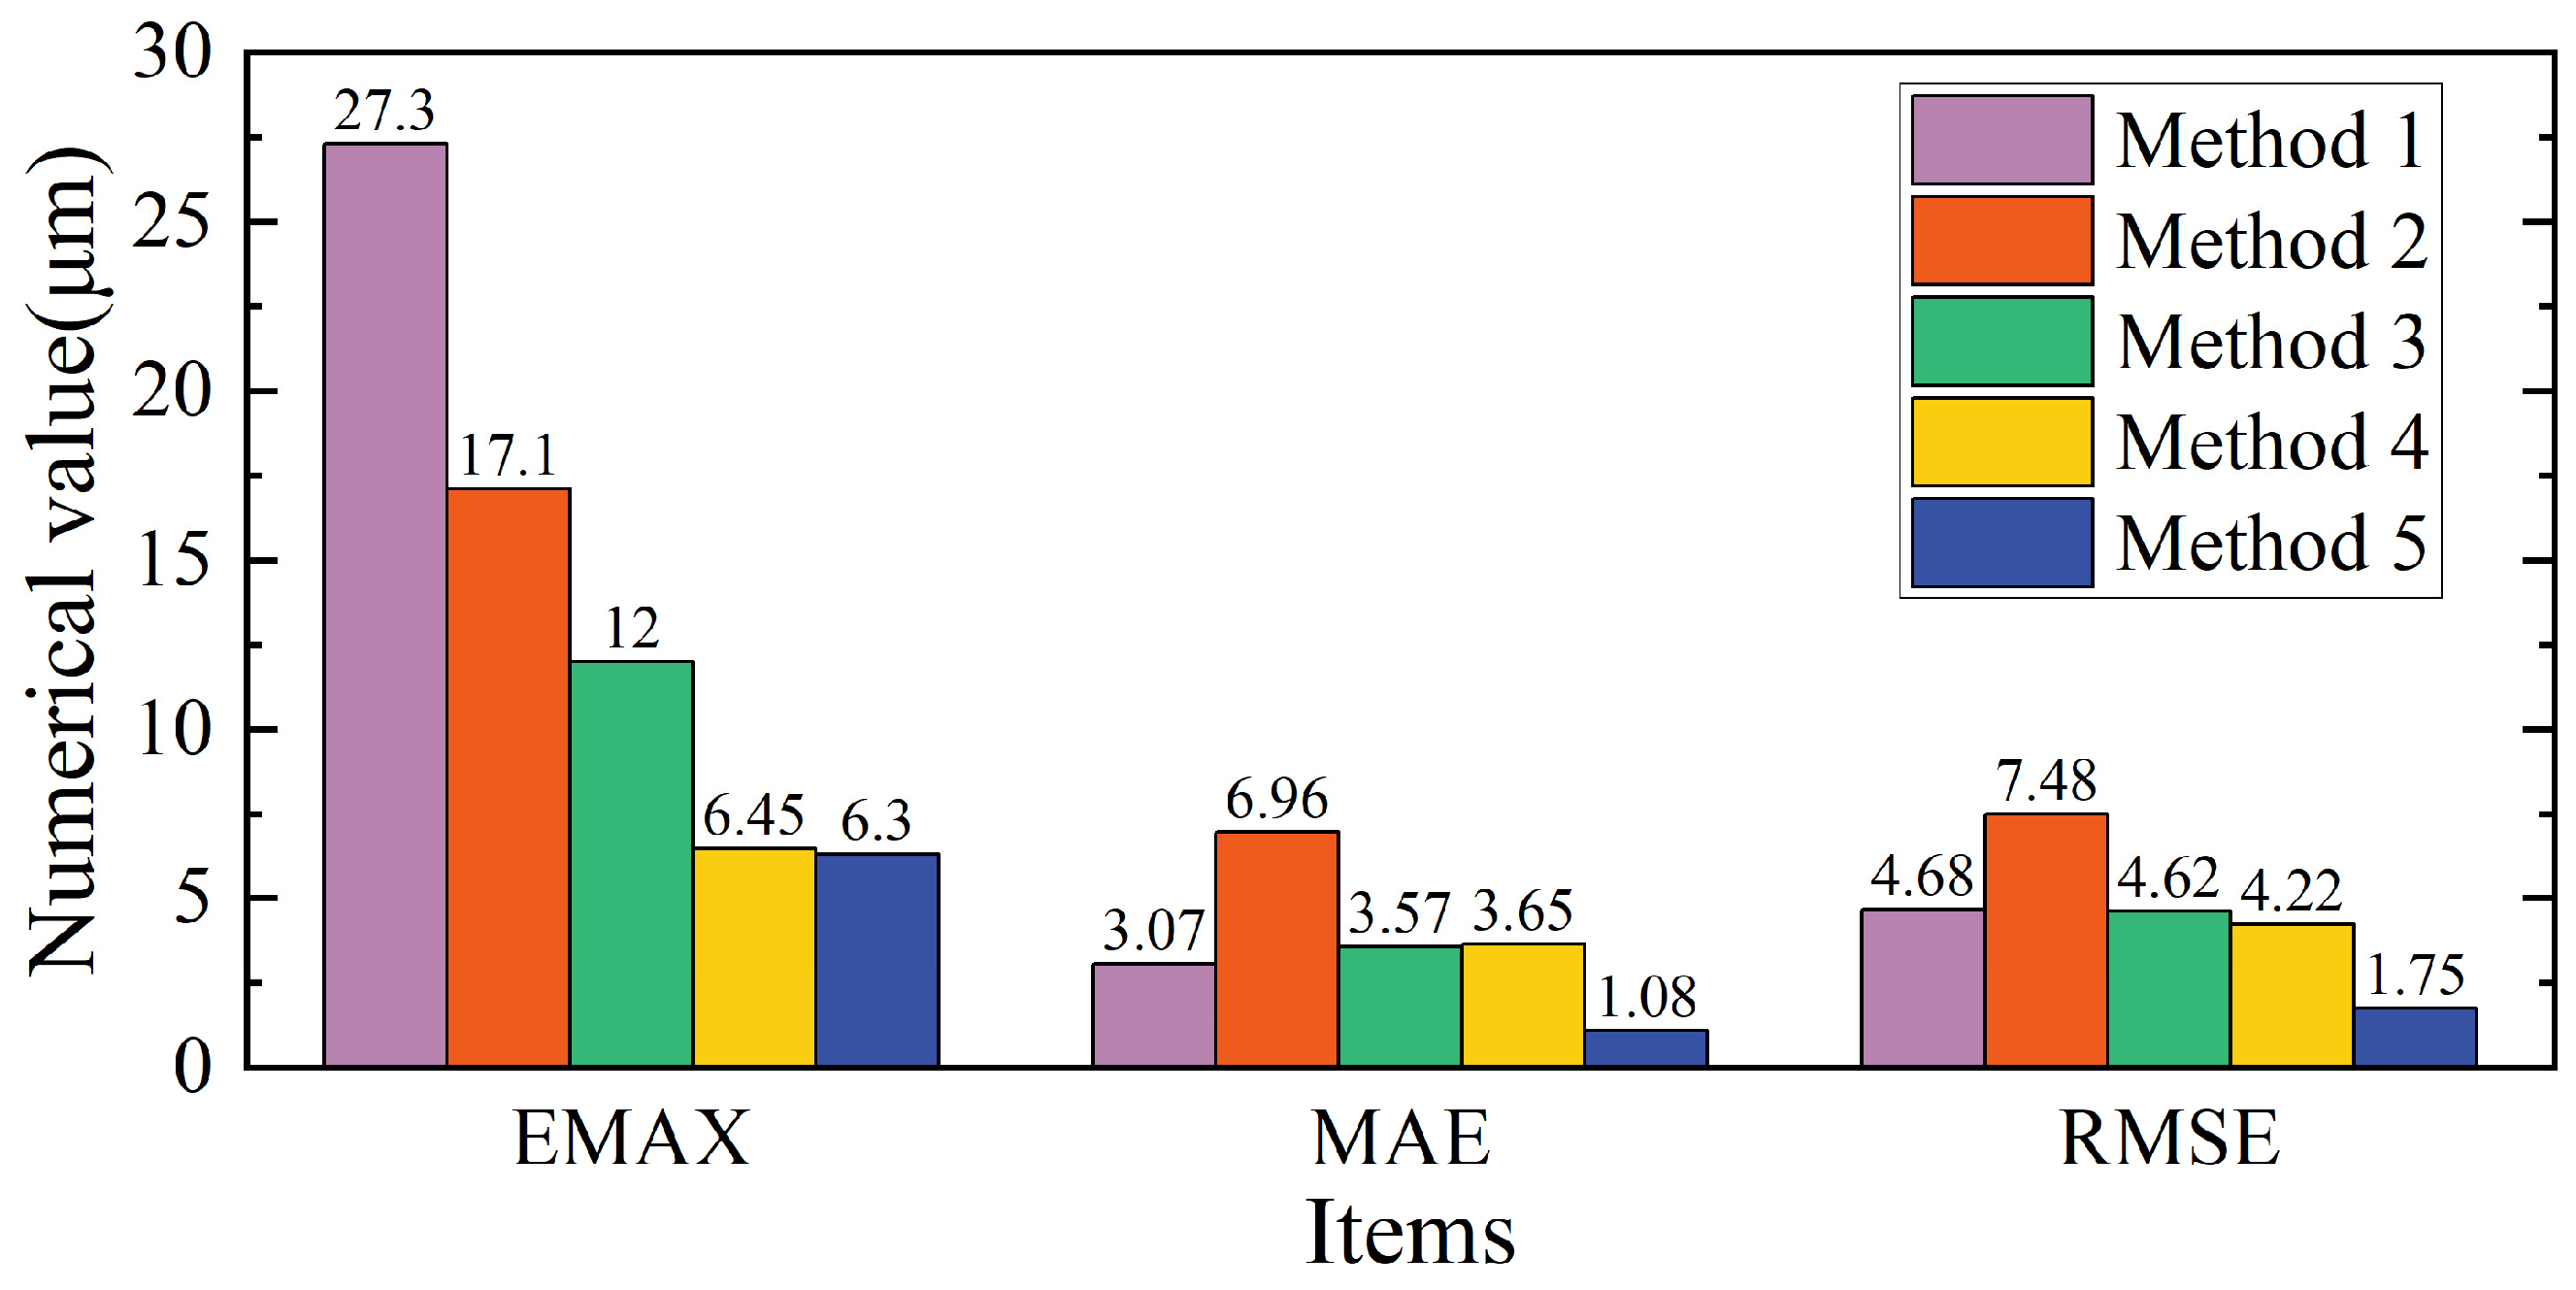
| Method | Nut Motor | Screw Motor |
|---|---|---|
| Method 1 | AFCC | |
| Method 2 | PD-FFFC | |
| Method 3 | GESO-SMC | |
| Method 4 | STSMO-SMC | |
| Method 5 | STSMO-SMC | ILFFC |
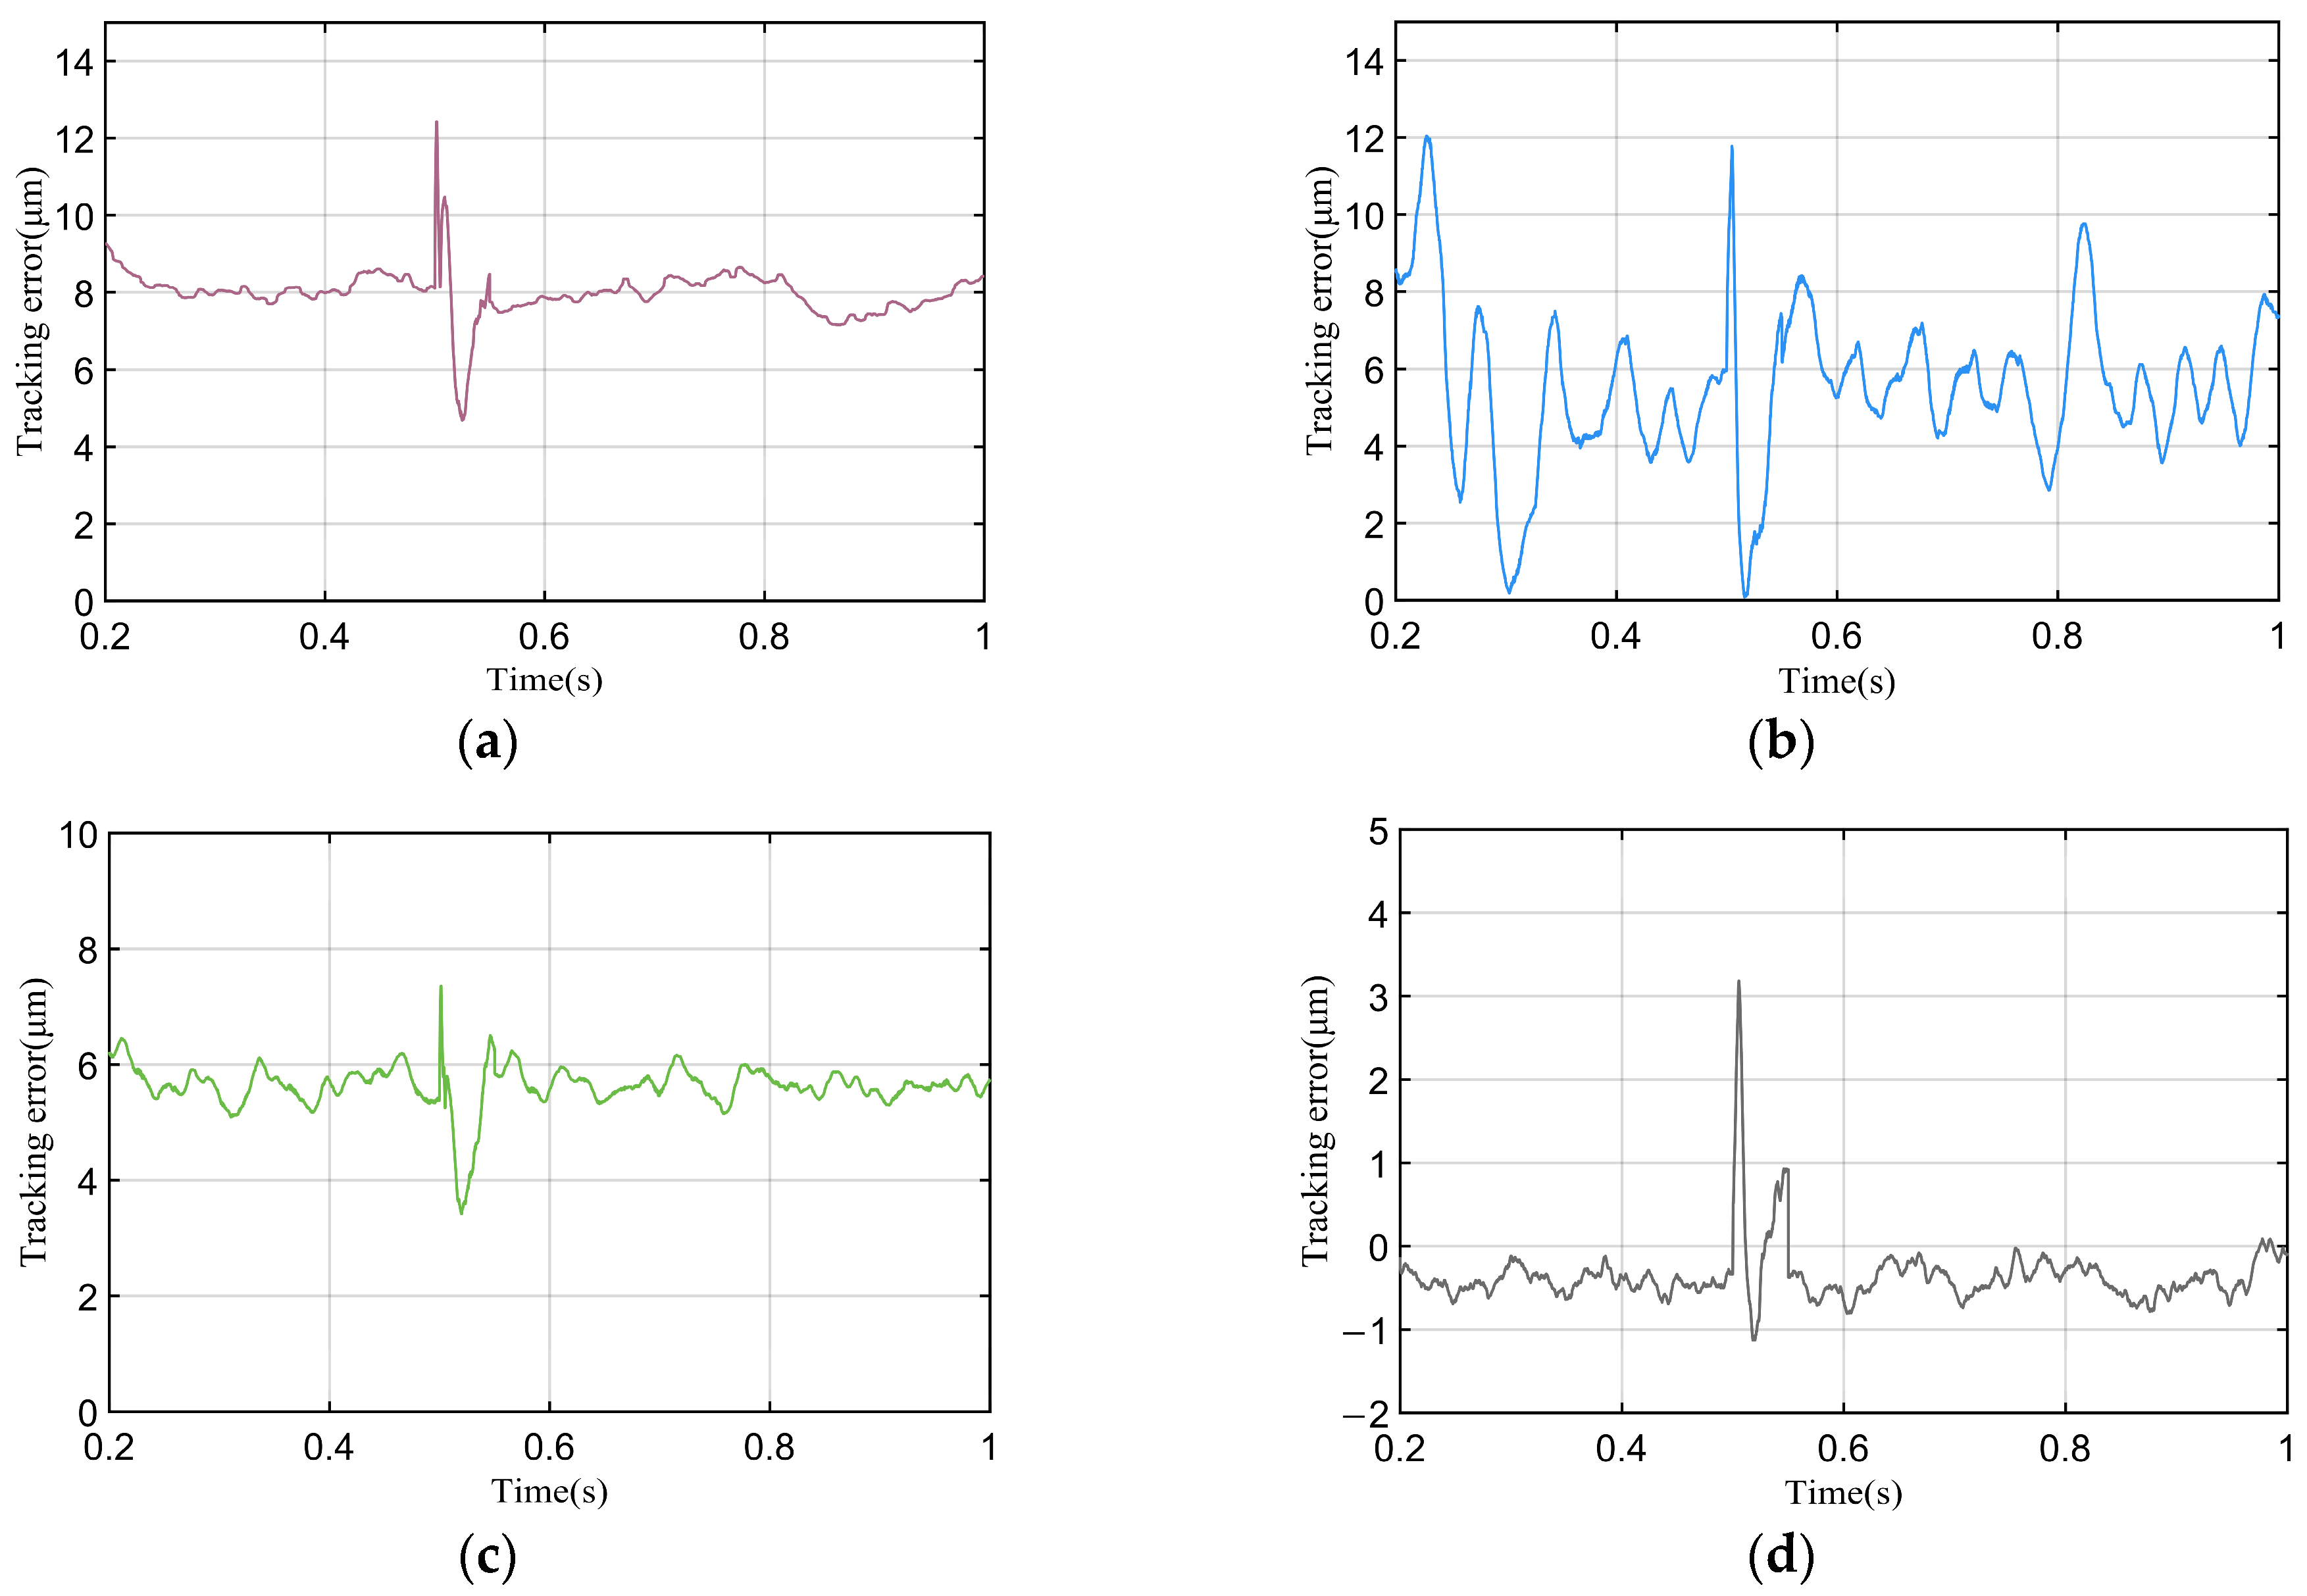
| Method | Maximum Error Change (μm) | Recovery Time (s) | RMSE (μm) |
|---|---|---|---|
| Method 2 | 7.8 | 0.093 | 7.96 |
| Method 3 | 12 | 0.081 | 9.83 |
| Method 4 | 3.9 | 0.045 | 5.64 |
| Method 5 | 4.2 | 0.048 | 4.32 |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Wang, A.; Feng, X.; Wang, H.; Yao, M. Design of Dual-Motor Drive Composite Control Strategy Based on Iterative Learning Feedforward Control and Super-Twisting Sliding Mode Observer. Actuators 2026, 15, 343. https://doi.org/10.3390/act15060343
Wang A, Feng X, Wang H, Yao M. Design of Dual-Motor Drive Composite Control Strategy Based on Iterative Learning Feedforward Control and Super-Twisting Sliding Mode Observer. Actuators. 2026; 15(6):343. https://doi.org/10.3390/act15060343
Chicago/Turabian StyleWang, Anning, Xianying Feng, Hao Wang, and Ming Yao. 2026. "Design of Dual-Motor Drive Composite Control Strategy Based on Iterative Learning Feedforward Control and Super-Twisting Sliding Mode Observer" Actuators 15, no. 6: 343. https://doi.org/10.3390/act15060343
APA StyleWang, A., Feng, X., Wang, H., & Yao, M. (2026). Design of Dual-Motor Drive Composite Control Strategy Based on Iterative Learning Feedforward Control and Super-Twisting Sliding Mode Observer. Actuators, 15(6), 343. https://doi.org/10.3390/act15060343