1. Introduction
Electromagnetic pneumatic systems have gained significant traction in industrial applications due to their superior speed compared to traditional pneumatic systems. Proportional control valves, as integral components of pneumatic systems, are employed to regulate the opening of the valve spool, thereby achieving the desired flow rate and pressure within the system. The overall performance of the system is contingent upon the functionality of the proportional control valve. In actual operating conditions, external sensors are often used in conjunction with proportional control valves to provide feedback to the actuators. However, due to the harsh operating environments in which they are employed, external sensors are prone to damage, which may result in economic losses and safety incidents. Consequently, there is a pressing need for research on the utilization of proportional control valves for direct flow regulation [
1]. At present, electromagnetic pneumatic valves employed for the regulation of airflow are predominantly classified into two categories: servo valves and quick-switching valves [
2]. Servo valves offer high precision and linearity but are expensive and structurally complex. Quick-switching valves are simple and inexpensive but have weaker linearity [
3].
Proportional control valves utilize the flow rate required for system operation as the control target, leveraging the measured flow rate as feedback to establish a closed-loop feedback control mechanism. Consequently, there is an imperative for research to be conducted on control strategies for electromagnetic pneumatic systems and the exploration of flow estimation methods. A considerable body of research has examined the modeling and control of electromagnetic pneumatic systems, with a predominant focus on cylinders and pneumatic valves [
4,
5,
6,
7,
8,
9]. Electromagnetic pneumatic systems utilize a range of control methodologies. In their research, Hadgson et al. developed an electromagnetic pneumatic system for robots, utilizing a sliding mode controller (SMC) to control cylinder position [
10]. Similarly, Leephakpreeda et al. developed a fuzzy logic controller (FLC) for pneumatic artificial muscles [
11] and evaluated the performance of the FLC for controlling high-precision pneumatic systems in simulations and experimental prototypes [
12]. In [
13], Swider et al. A proposed control scheme utilizes a PIC microcontroller. Taghizadeh et al. [
14] investigated the influence of pneumatic loops on input-output behavior and enhanced control performance using a controller based on a linear strategy rather than a nonlinear scheme.
Furthermore, scholars have conducted extensive research on flow estimation measurement methods. Xie et al. [
15] noted that the flow emission coefficient demonstrates substantial nonlinearity under conditions of valve opening and pressure difference. To account for this nonlinearity, the emission coefficient was determined through computational fluid dynamics (CFD) simulation. Valdés et al. [
16] derived flow coefficients by introducing functions based on the Reynolds number. Reference [
17] proposed an experimental procedure to evaluate the emission coefficient as a function of valve opening area, pressure difference, and temperature. Zhang et al. [
18] implemented an AdaBoost neural network to infer flow measurements, establishing correlations between flow velocity and various factors, including slide valve displacement, pressure difference, and temperature. In light of these findings, the researchers implemented AdaBoost technology to address the overfitting issue arising from the learning process within the BP neural network, thereby enhancing the model’s precision. Åman et al. [
19] adopted a cubic polynomial equation, utilizing pressure difference as an independent variable for flow rate calculation, thereby attaining a balance between accuracy and computational efficiency. Ding et al. [
20] refined the aforementioned method by incorporating particle swarm optimization to optimize the parameters of the BP neural network. Sitte et al. [
21] employed the aforementioned three techniques to infer the flow measurement of the seat valve and conducted a comparison, ultimately concluding that the most accurate fitting results were obtained.
While the aforementioned methodologies have yielded satisfactory outcomes in the domains of pneumatic system control and flow estimation, significant challenges persist in their practical implementation. Existing pneumatic control system research generally struggles to balance control accuracy and computational efficiency under nonlinear dynamic characteristics and complex noise interference. The operational characteristics of pneumatic proportional electromagnetic valves frequently manifest nonlinear features, including flow-pressure characteristics and opening-flow characteristics. This nonlinearity poses significant challenges in the design and implementation of control algorithms, making it difficult to accurately describe and predict the behavior of electromagnetic valves. Additionally, electromagnetic interference and mechanical vibrations in industrial environments have been shown to cause sensor signal distortion, significantly reducing the accuracy of flow estimation measurements. Noise interference has been identified as a significant problem. For instance, flow sensors have been shown to produce erroneous readings due to noise, resulting in deviations in the control system’s adjustment of the pneumatic electromagnetic proportional valve’s opening. This, in turn, has been observed to affect the control accuracy of gas flow. Furthermore, the presence of noise has been demonstrated to exert an influence on the computational and decision-making processes of the controller. The presence of noise in input or feedback signals may cause the controller to make incorrect judgments, resulting in the issuance of incorrect control commands and further reducing control accuracy. On the other hand, existing control algorithms are mostly based on pre-set models and parameters, lacking self-learning capabilities, and heavily reliant on high-precision flow sensors, which come with issues such as high costs, susceptibility to damage, and difficult maintenance.
While advanced nonlinear control strategies have been successfully applied to pneumatic muscle actuators in rehabilitation applications [
22,
23], these methods typically focus on position tracking and human–robot interaction, where model uncertainties are addressed through disturbance observers or sliding mode control. In contrast, the present work targets industrial proportional valve flow control, where the primary challenges are flow nonlinearity, sensor noise, and embedded hardware constraints. The proposed fuzzy PID + IWT framework offers a lightweight solution suitable for real-time implementation on low-cost microcontrollers, which distinguishes it from computationally intensive approaches required in rehabilitation exoskeletons.
The proposed study presents a cooperative control framework that integrates a fuzzy PID and an enhanced wavelet threshold (IWT) mechanism. The fuzzy PID parameters (, , ) are dynamically adjusted using fuzzy rules, thereby compensating for the nonlinear characteristics inherent in the electromagnetic pneumatic system, including the LuGre friction memory effect. The experimental findings indicate that the overshoot is diminished by 35% in comparison to the conventional PID. The proposed approach involves the implementation of an adaptive wavelet threshold denoising algorithm, a sophisticated mathematical model that integrates a decaying sine function with an exponential noise reduction mode. This innovative approach effectively suppresses high-frequency noise while preserving the nuances of the flow signal, thereby enhancing the signal-to-noise ratio (SNR) by 65% and reducing the root mean square error (RMSE) by 49%. The algorithm’s efficacy is further validated through its integration of electromagnetic, mechanical, and fluid dynamics models—a multifaceted fusion enabling multiphysics field coupling simulations. By eliminating reliance on high-cost external sensors, the method substantially mitigates maintenance risks in harsh operating environments. This system delivers a high precision, robust flow control solution for industrial proportional valves, thereby offering direct industrial application value.
The overall control pipeline proceeds as follows: (a) Multi-physics modeling (
Section 2), the proportional valve flow equation, LuGre friction model, cylinder pressure differential equation, and force equilibrium equation are coupled to form the plant model. (b) Fuzzy PID controller design (
Section 3), the error e and error change rate ė between the target and actual flow are used as inputs; fuzzy inference dynamically adjusts
,
,
online to compensate for plant nonlinearity. (c) Improved wavelet threshold (IWT) denoising (
Section 4), noisy sensor signals are processed via adaptive wavelet thresholding before being fed back to the controller, improving signal-to-noise ratio. (d) Experimental validation (
Section 5), fuzzy PID control performance, denoising effectiveness, and multi-method flow estimation comparisons are presented.
3. Fuzzy PID Controller Design
Having established the multi-physics coupling model of the proportional valve system in
Section 2, this section addresses the design of the fuzzy PID controller that operates on the estimated flow signal to dynamically compensate for the plant nonlinearities identified above.
3.1. Control Objectives and Structure
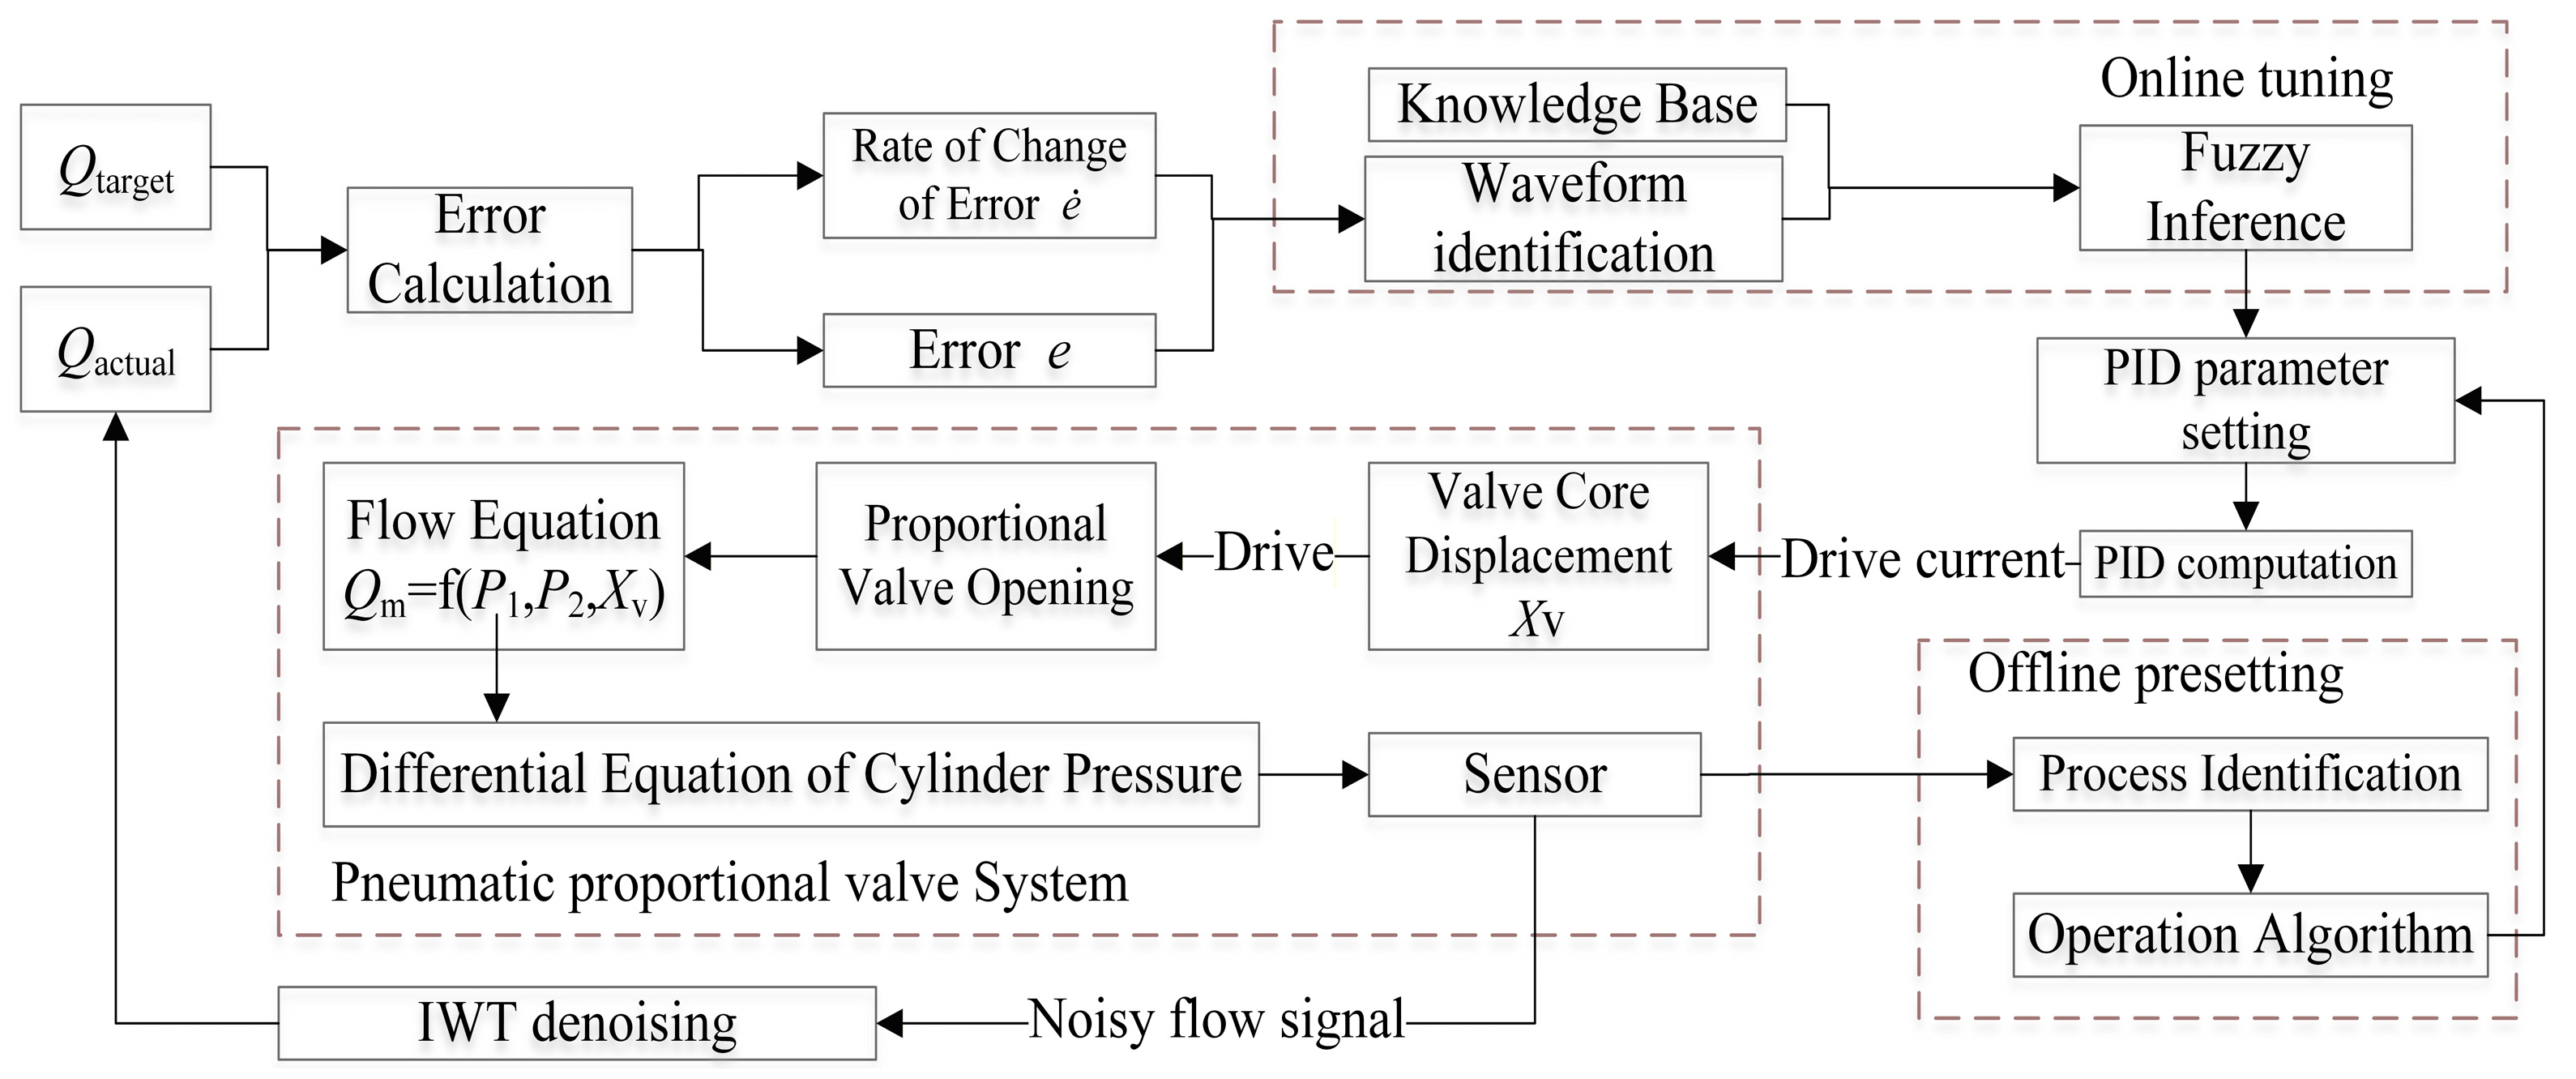
In order to address the parameter time-varying issue caused by the nonlinearity of the proportional valve, the employment of fuzzy control rules has been proposed to modify the PID parameters online. This modification constitutes a fuzzy self-tuning PID controller [
25,
26], the structure of which is shown in
Figure 6. The establishment of a fuzzy inference mechanism is based on the performance requirements of the electromagnetic pneumatic system. The purpose of this establishment is twofold: first, to eliminate the influence of unmodeled dynamic characteristics, and second, to enhance the robustness of the controller. The fuzzy inference component is responsible for monitoring the waveform of the control response in real time to calculate performance metrics such as rise time, overshoot, and steady-state error.
3.2. Setting Fuzzy Language Variables
The system deviation e and the deviation change rate
are utilized as input language variables for the fuzzy controller, while the parameters
,
and
are employed as output language variables. The variation in these systems is defined by the fundamental domains of fuzzy sets:
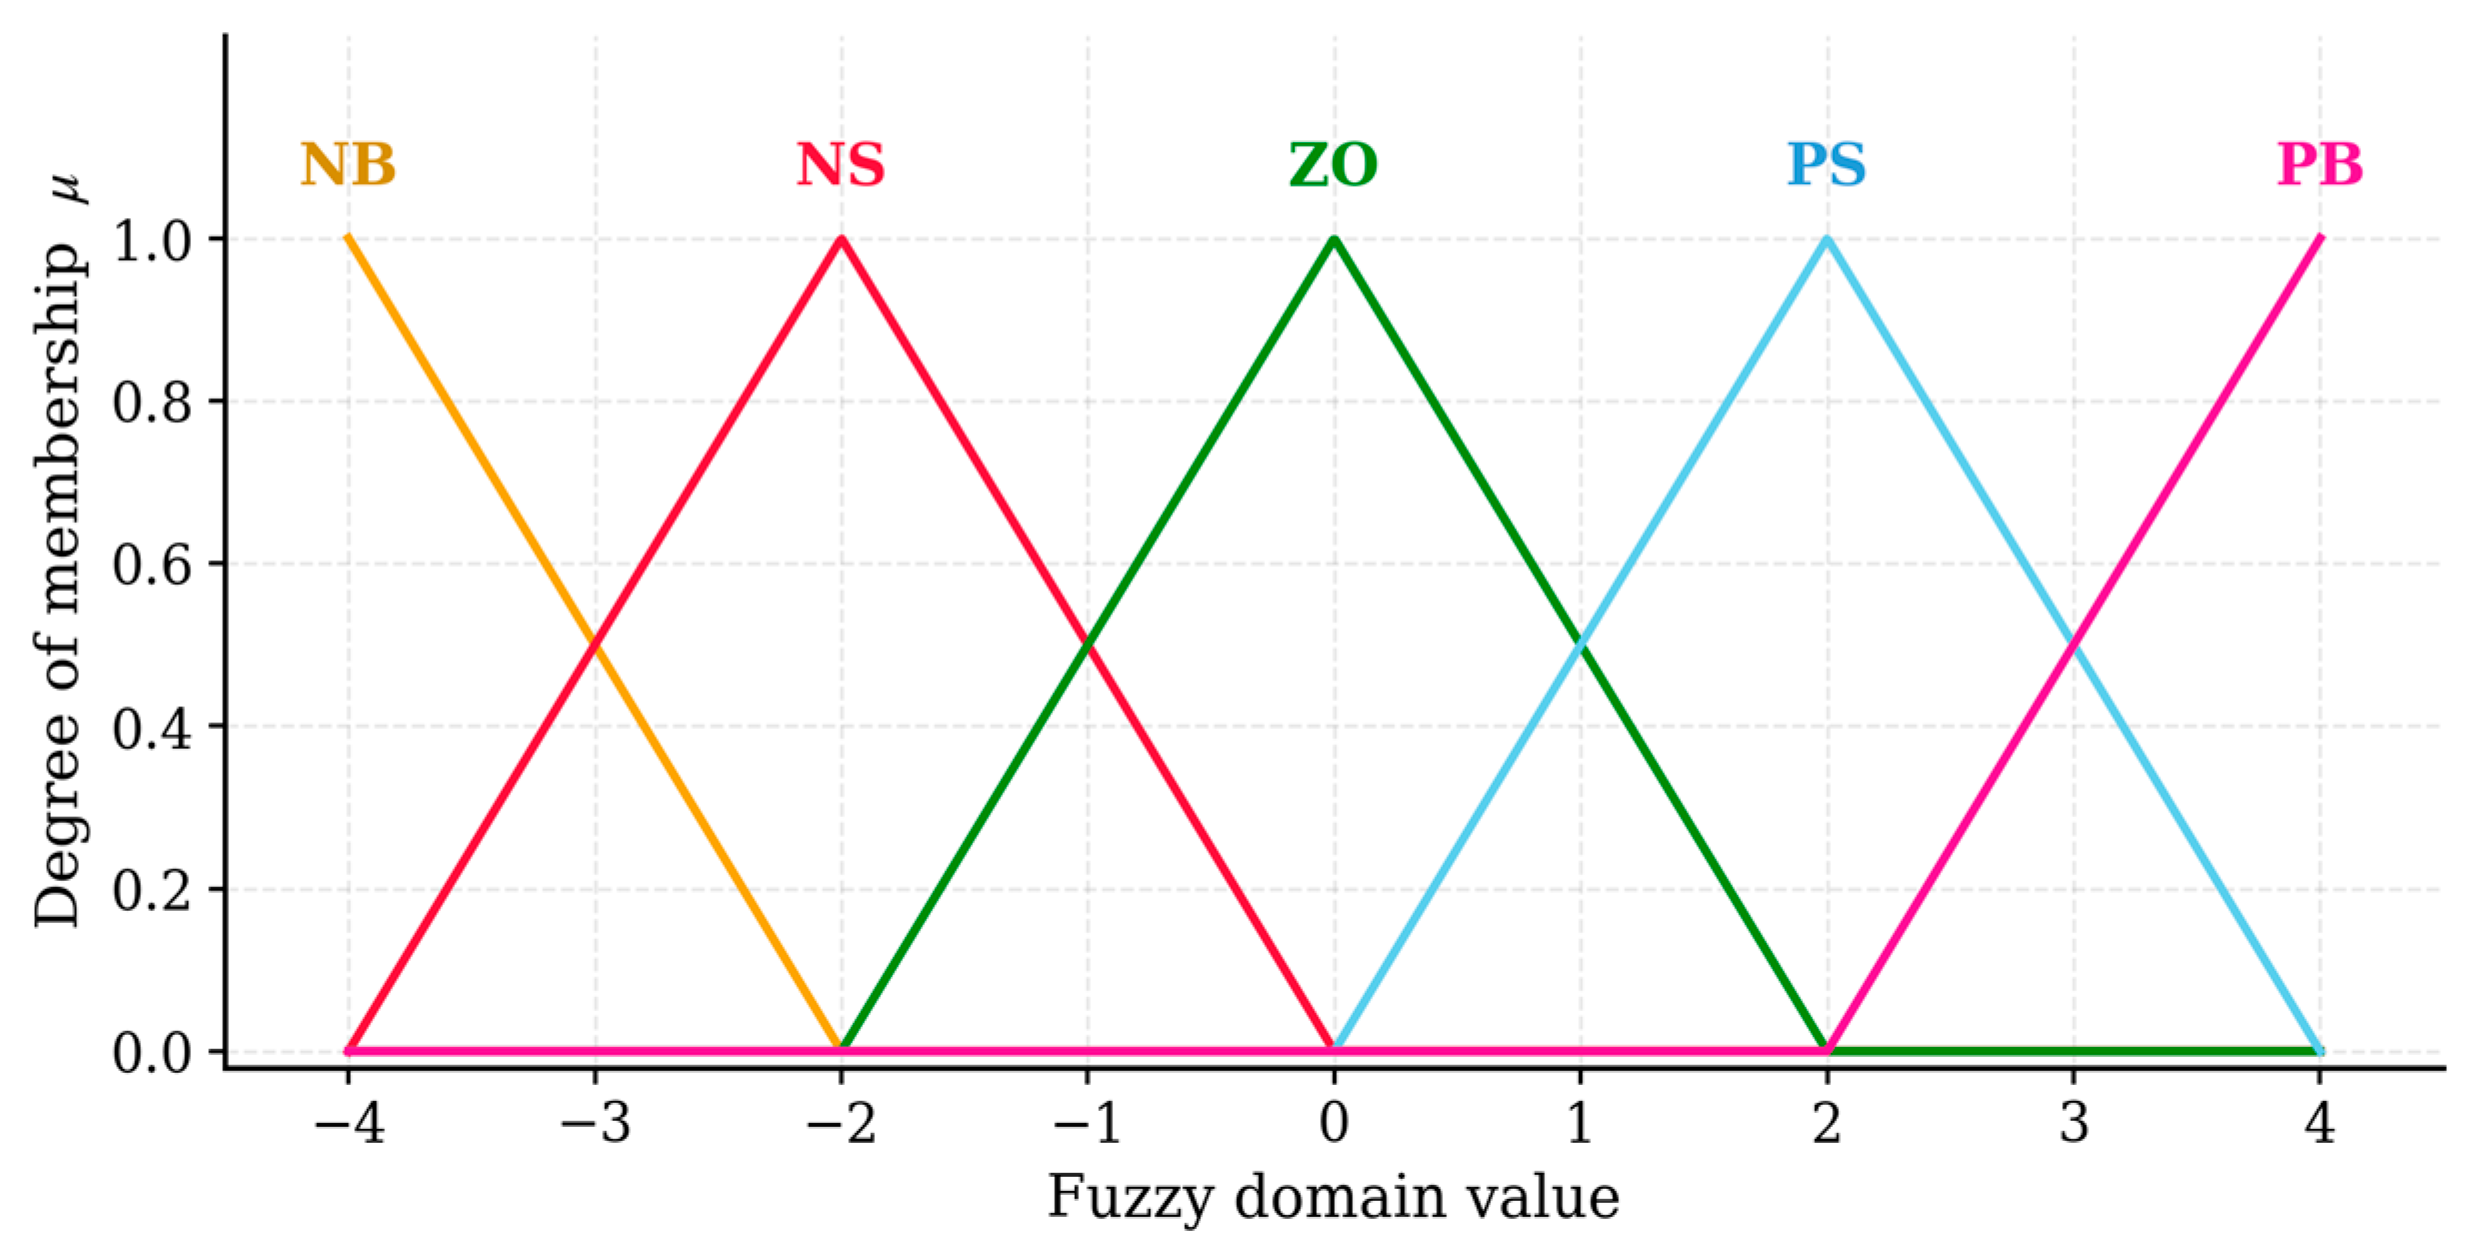
Its fuzzy subset is denoted by , and the elements in the subset represent negative large, negative small, zero, positive small, and positive large, respectively.
The continuously varying quantities within the basic domain are to be divided into discrete levels, followed by the implementation of fuzzy processing. The range of variation for the speed deviation e and the deviation change rate e of the secondary element is specified as [−4, 4]. In the event that the values fall outside this interval, they can be converted to the range [−4, 4] using the linear transformation Formula (15).
The membership functions employed for each fuzzy state are typically selected from a range of options, including symmetric triangular, symmetric trapezoidal, and normal-type functions. The underlying reason for this phenomenon is that the configuration of a triangular membership function is contingent upon the gradient of its corresponding straight line. This attribute of the function renders the computational process more straightforward and reduces the requirement for memory storage. Consequently, it is especially well-suited for fuzzy control systems in which membership functions must be adjusted in real time. In such scenarios, a triangular membership function is chosen for the language variable, as illustrated in
Figure 7.
Indeed, the configuration of the membership function-whether triangular, trapezoidal, or of a normal distribution, among others-exerts minimal influence on the control performance. Conversely, the extent of each fuzzy subset’s coverage over the entire domain demonstrates a substantial impact on performance. Consequently, the membership functions previously employed are still applicable. Consequently, the assignment tables for the membership degrees , and can be determined.
3.3. Fuzzy Rules
Control rules constitute the fundamental components of fuzzy controllers. A substantial body of research has been dedicated to the development of effective control strategies, which are then refined through a process of organization, processing, and refinement. These strategies are described using the fuzzy states of input and output variables to establish control rules.
The output parameters of the PID controller are represented by the following formulas:
The range of the error and the error change in a fuzzy controller is referred to as the basic domain of these variables. In order to execute the process of fuzzy processing, it is necessary to transform the basic domains of the input error and error change into the domains of the corresponding fuzzy sets. This transformation requires the application of a quantization factor. Concurrently, the range of control quantity changes required by the controlled object is referred to as the basic domain of the input quantity. When transferring the control quantity obtained from the fuzzy control algorithm to the basic domain, it is imperative that the quantity be multiplied by a proportionality factor. The following variables are introduced: the error and error rate input quantization factors and , as well as the output transformation proportionality factor .
The input quantization factors
and
, as well as the output transformation ratio factor
, have been demonstrated to have a significant impact on the dynamic and static performance of the system. Therefore, it is imperative that they be selected with precision. The input quantization factor is contingent upon the maximum overshoot in the response curve, while the output ratio factor is influenced by the initial PID parameters and is also associated with the desired response performance.
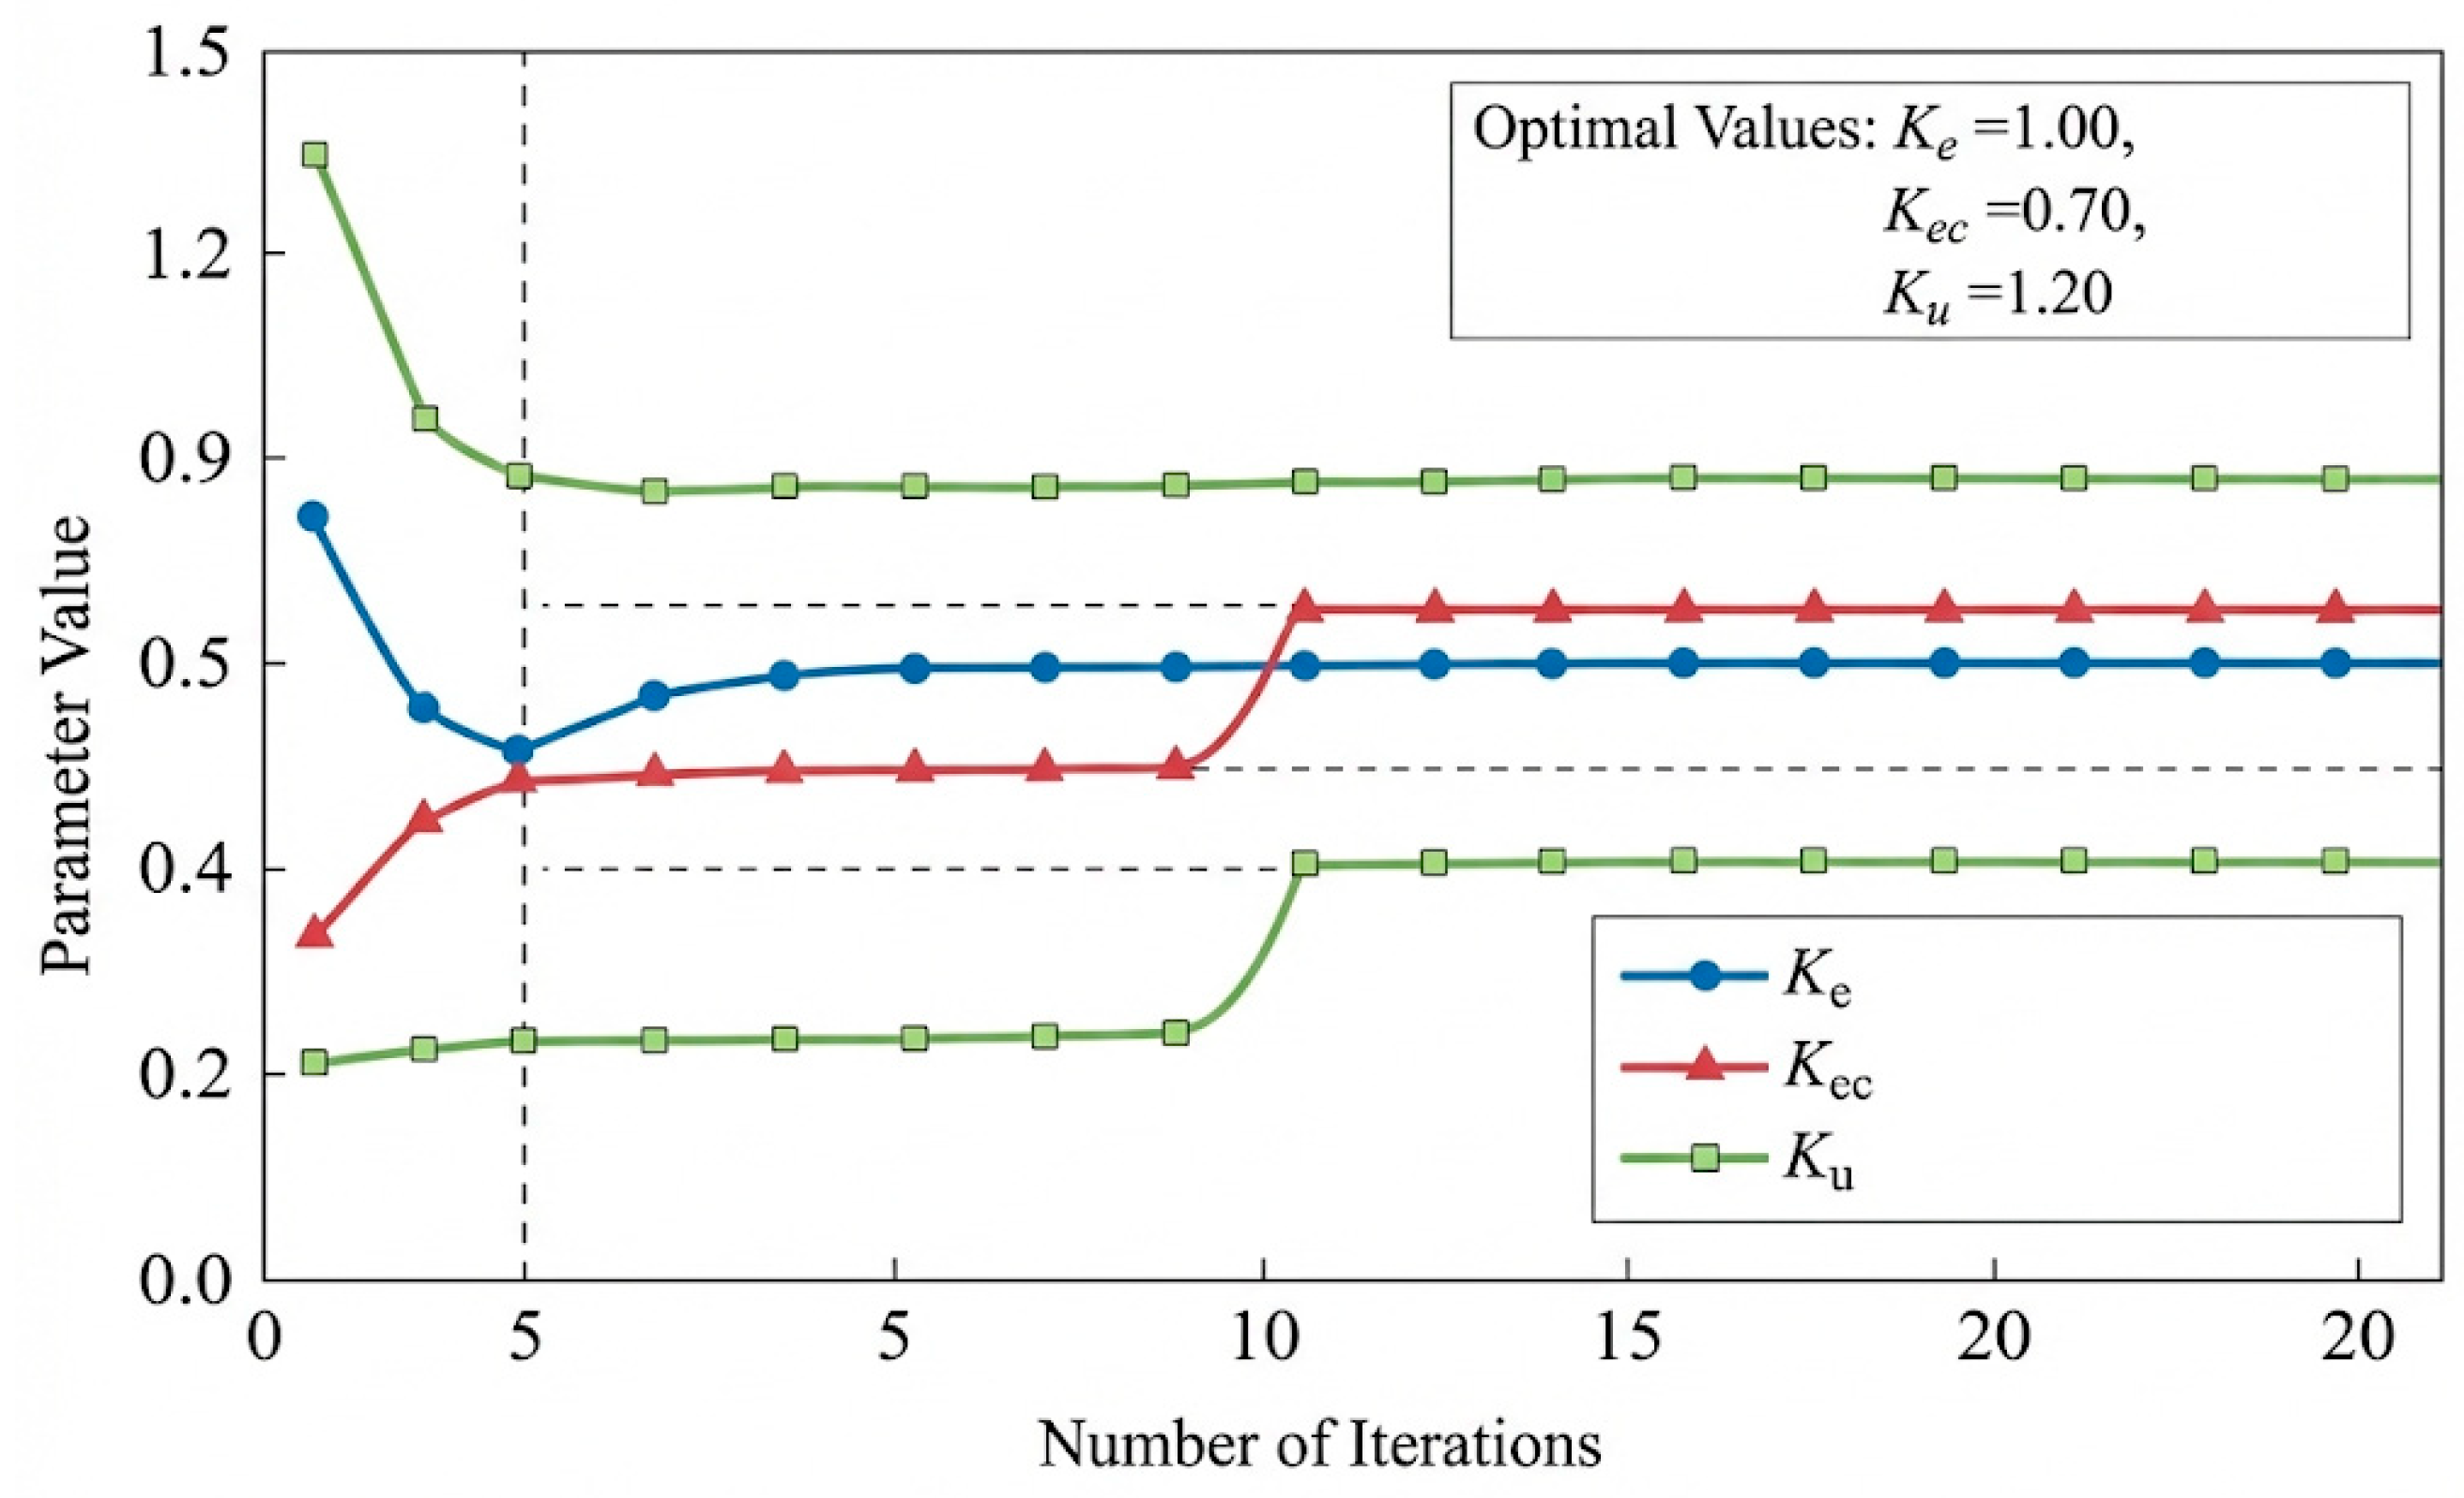
In order to ensure the rationality and repeatability of fuzzy PID controller parameter tuning, this paper systematically explains the selection of error quantization factor , error change rate quantization factor and output scale factor .
Among them, and are mainly used to map the actual error and error change rate to the fuzzy universe, and their values are determined according to the maximum steady-state error and the maximum error change rate in the system step response; is used to reflect the fuzzy reasoning results into the actual PID parameter adjustment amplitude, and their initial values are obtained according to the Ziegler-Nichols critical proportion method.
On this basis, this paper further uses the parameter sensitivity analysis method to simulate
,
and
within a variation range of ± 20%. Taking the overshoot, adjustment time and steady-state error as evaluation indicators, the optimal parameter combination is finally determined. The results show that this parameter configuration ensures rapid response of the system while significantly suppresses the oscillation caused by friction nonlinearity. The sensitivity analysis of fuzzy PID parameters is shown in
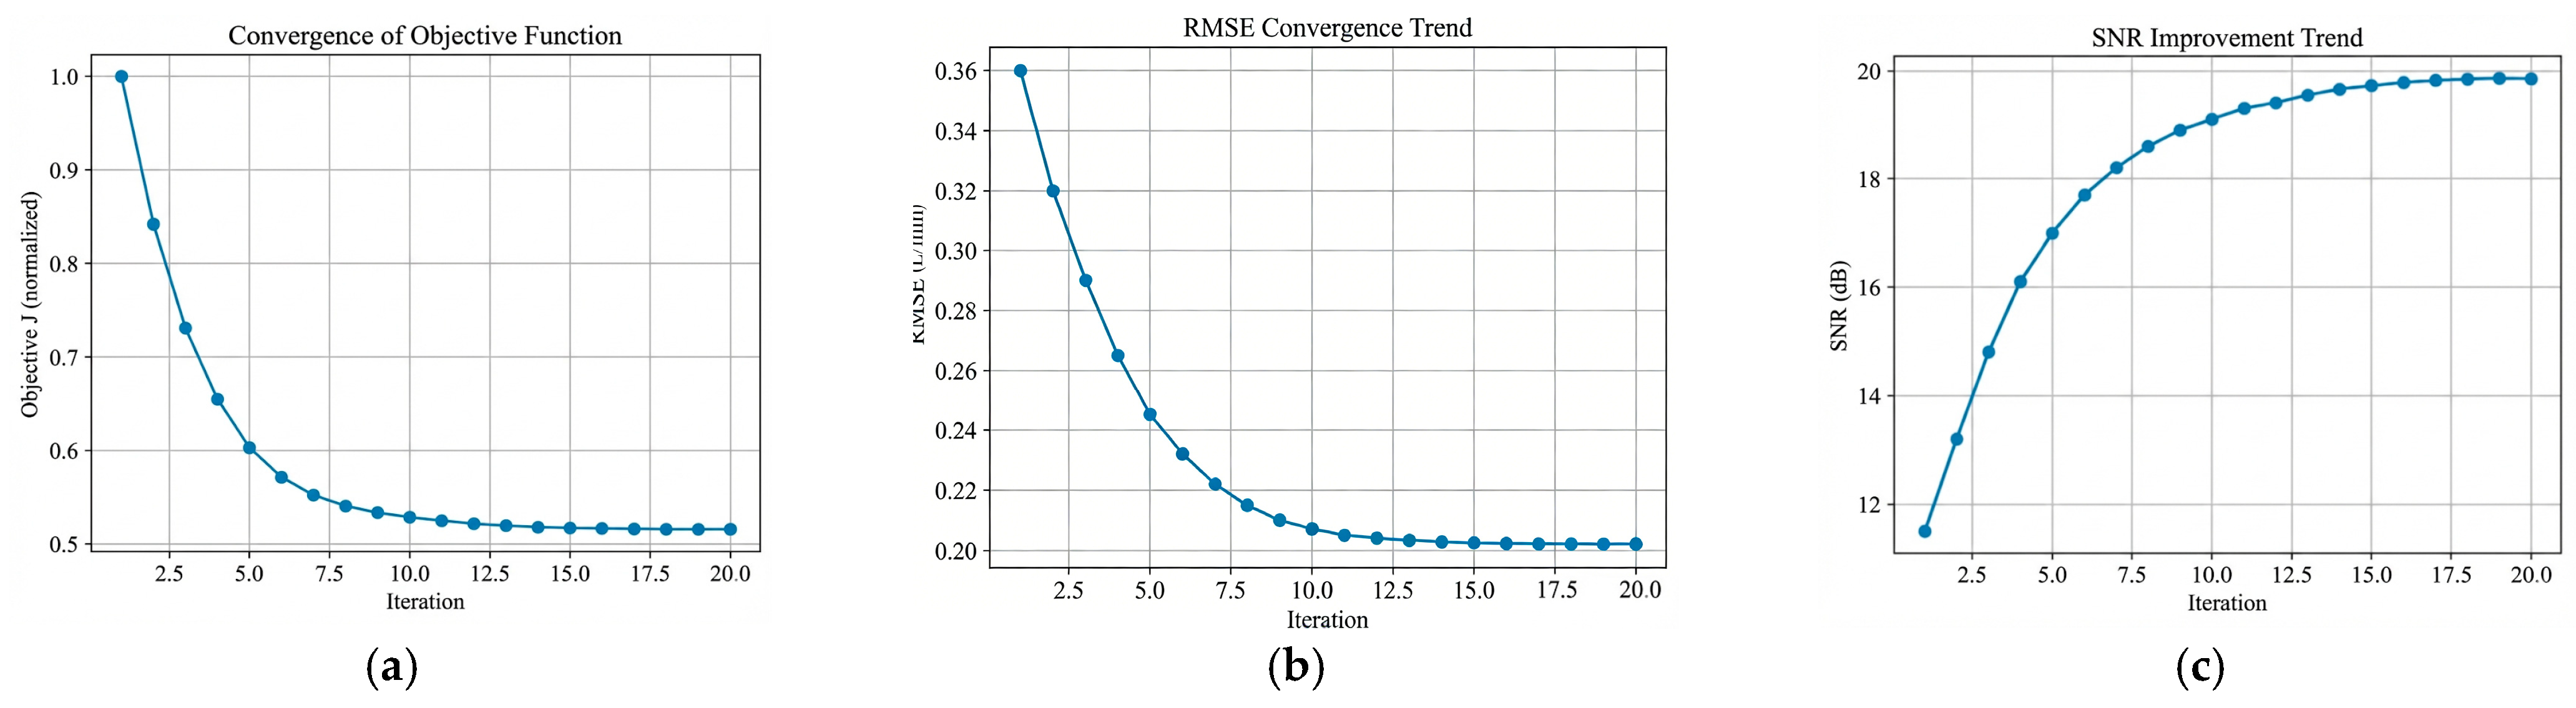
Table 2. The parameter optimization process is given, as shown in
Figure 8.
We note that the sensitivity analysis presented in
Table 2 adopts a simultaneous perturbation approach, in which all three parameters (
) are varied by the same percentage simultaneously. This choice was made for the following reasons:
(1) Physical coupling: In the fuzzy PID framework, the three quantization/scaling factors are not independent design variables but are functionally coupled through the fuzzy inference process. Specifically, and jointly determine the operating point within the fuzzy rule table, while scales the output. Perturbing one factor while fixing the others may yield misleading sensitivity indices because the fixed factors would no longer correspond to their optimal values for the perturbed system.
(2) Worst-case robustness: Simultaneous perturbation represents the most conservative (worst-case) scenario for parameter uncertainty, as all parameters deviate from their nominal values at the same time. If the system maintains satisfactory performance under this condition, it is guaranteed to perform at least as well under any single-factor perturbation of the same magnitude.
(3) Practical relevance: In real-world deployment, parameter deviations due to component aging, environmental changes, or calibration errors tend to affect multiple parameters simultaneously rather than in isolation.
The results in
Table 2 demonstrate that the system performance degrades gracefully under simultaneous perturbation of up to ±20%, with overshoot remaining below 7.8% and steady-state error below 0.48 mm. This provides strong evidence of robustness for practical applications.
The total fuzzy relationship between,
,
, and
is as follows:
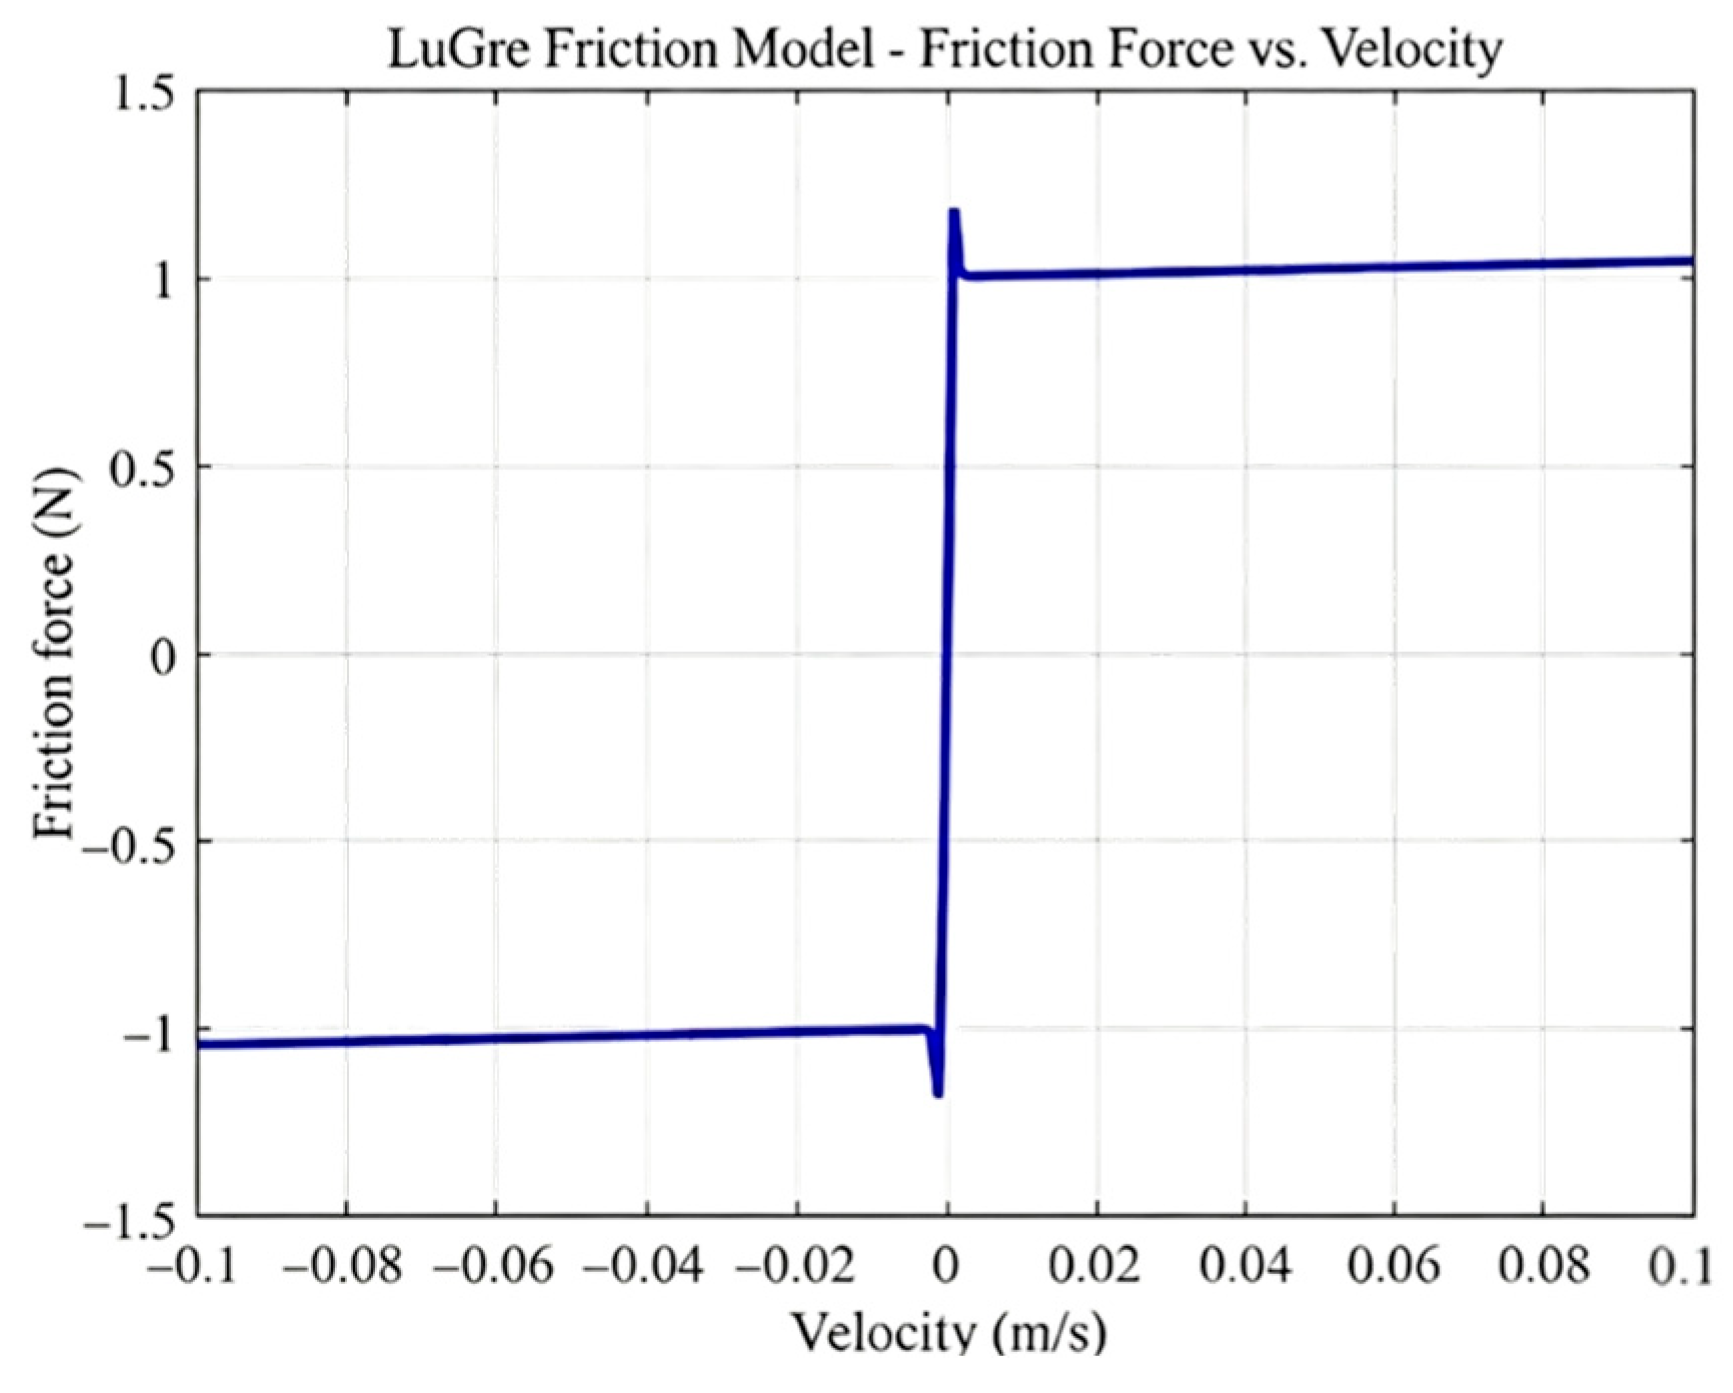
The core principle of fuzzy PID control lies in employing fuzzy rules to dynamically adjust controller parameters. In electromagnetic pneumatic systems, primary nonlinearities stem from the LuGre friction model’s memory effect, flow equation pressure dependence, and dynamic cylinder load disturbances. Rule table design integrates these nonlinear characteristics with system dynamics and empirical knowledge. When the error () and error rate () belong to different fuzzy states, , , and are adaptively tuned to enhance control performance. For significant negative displacement errors, is set to “positive large (PB)” to correct steady-state error quickly, is gradually increased to accelerate convergence, while is reduced to avoid high-frequency oscillations caused by friction memory. As the valve spool nears the target, all gains converge to “zero (ZE),” ensuring smooth transitions and minimizing overshoot from pressure fluctuations. In overshoot scenarios, switches to “negative large (NB)” for rapid correction, and is increased to mitigate inertial effects from sudden load changes. When the error rate crosses zero, is set to “positive small (PS),” enhancing differential action to compensate for bristle deformation dynamics in the LuGre model and suppress oscillations. Finally, fuzzy outputs are defuzzified into precise control signals.
3.4. Defuzzification
The results of fuzzy reasoning, that is to say, the output variables of the fuzzy controller, are generally fuzzy sets that cannot be directly used to control the controlled object. The initial step involves the conversion of the variables into precise quantities that can be executed by the actuator. This process is commonly referred to as defuzzification, and the center of gravity method is a widely used defuzzification method in fuzzy control systems.
The variable z is the center of the area covered by the membership function of the fuzzy set:
It is imperative to acknowledge that the precise values of the output variables obtained through defuzzification are exclusively the exact values within their respective domains. Furthermore, contingent on the domain of the output variable and the fuzzy state, the domain-specific exact value of the output variable must undergo conversion back to its corresponding actual exact value through the inverse process of converting the actual exact value of the input variable into a domain-specific exact value. The resulting precise value of the output variable can then be used as the exact quantity that the fuzzy controller transmits to the actuator for control of the controlled object.
3.5. Stability and Parametric Disturbance Analysis
In essence, fuzzy PID controllers can be regarded as a kind of time-varying PID controllers whose parameters are adjusted online. Under the conditions of small system errors and stable operating points, the fuzzy inference output tends to be constant, and the controller is equivalent to a linear PID structure. At this time, the system stability can be analyzed with reference to the classic PID closed-loop stability conditions.
To provide a formal stability argument, we adopt the framework of Lyapunov-based analysis for bounded-parameter time-varying systems. Define the Lyapunov function candidate as
where
denotes the tracking error. The time derivative along the closed-loop trajectory yields:
Under fuzzy PID control, the control output is expressed as
where
,
,
are online-tuned by the fuzzy inference engine. The key structural property is that the fuzzy rule base confines the PID gains within predetermined bounds:
These bounds are explicitly enforced by the fuzzy universe boundaries (range [−4, 4] as defined in
Section 3.2) and the output scaling factor
. Within this bounded parameter set, for any admissible combination (
), the equivalent linear PID controller satisfies the Routh–Hurwitz stability criterion for the linearized plant model derived. Consequently,
for all
within the operating region, guaranteeing local asymptotic stability.
Furthermore, since the fuzzy rule adjustment is memoryless (i.e., the parameter update at each instant depends only on the current
and
, not on past values), the closed-loop system can be modeled as a linear parameter-varying (LPV) system with polytopic uncertainty. The stability of such systems is guaranteed if a common Lyapunov function exists for all vertex controllers—a condition satisfied here because the Routh–Hurwitz conditions hold for all four corner points of the (
) parameter box. The simulation results presented in
Table 3 and
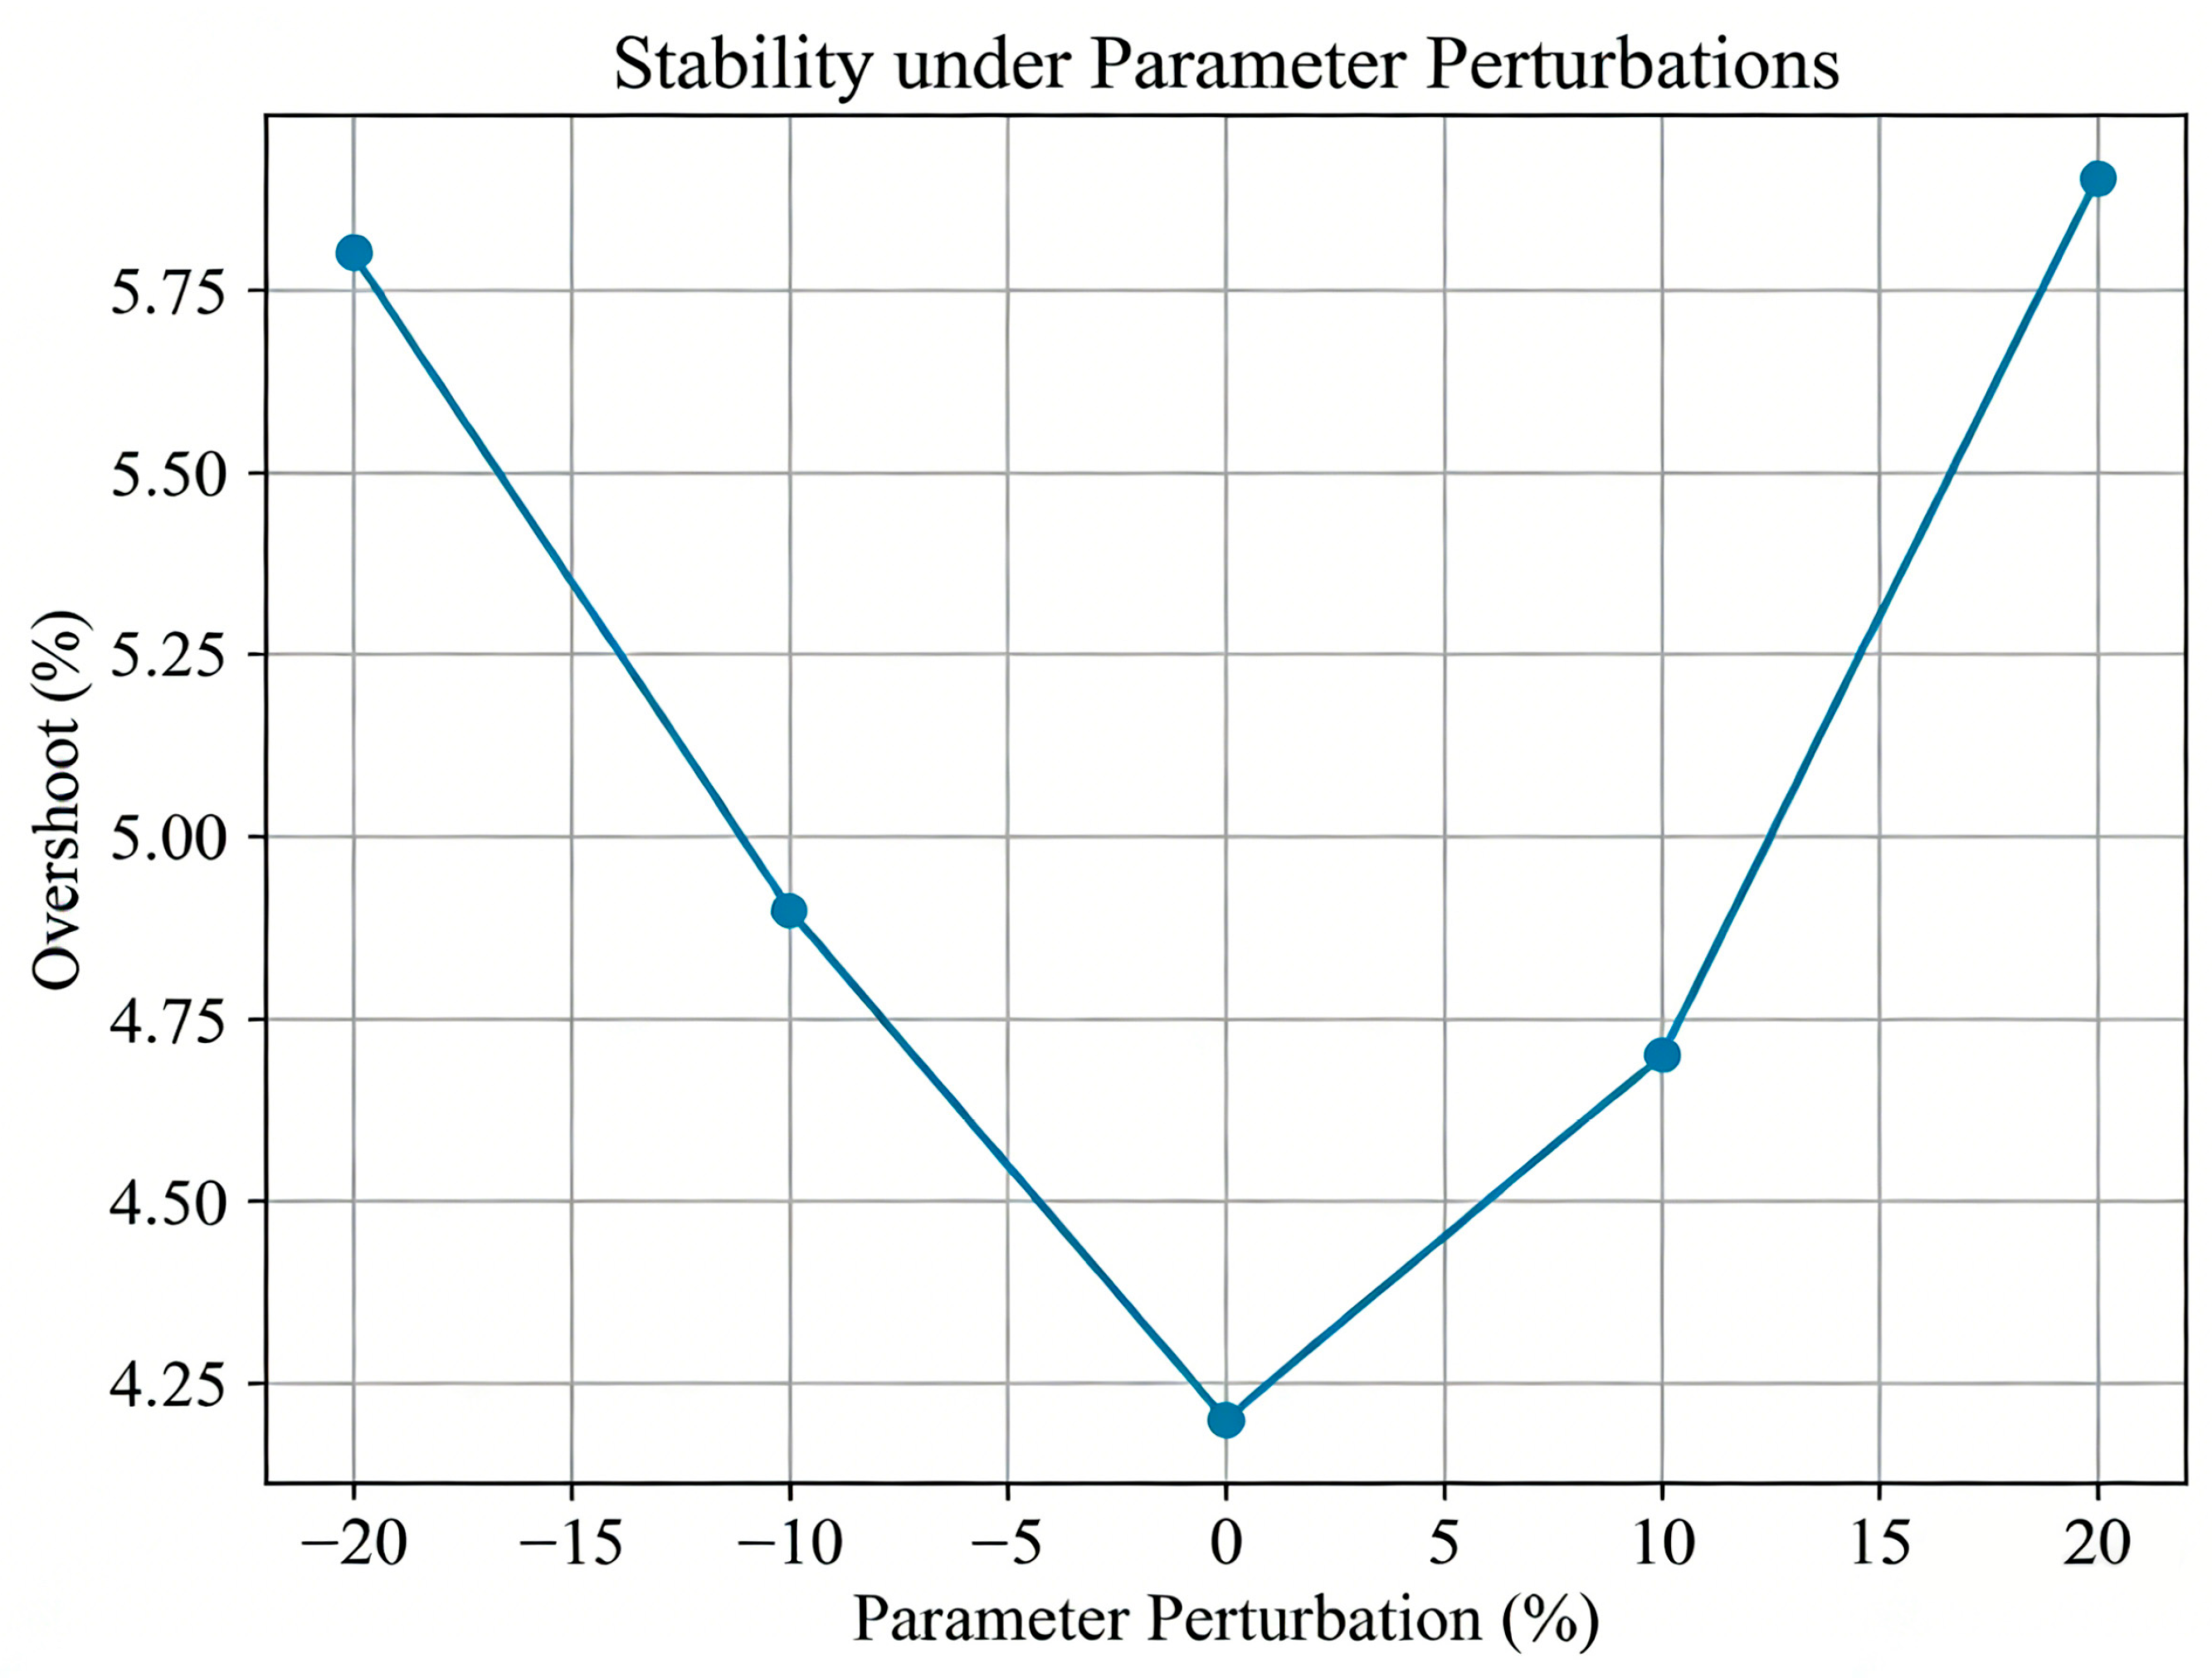
Figure 9 confirm this theoretical prediction: the system remains asymptotically stable under ±20% parameter perturbation with bounded overshoot (≤5.9%) and settling time (≤0.79 s).
We acknowledge that a rigorous global stability proof for the full nonlinear system (incorporating the LuGre friction model and compressible flow dynamics) would require advanced tools such as integral quadratic constraints (IQCs) or sum-of-squares (SOS) programming, which is beyond the scope of the current work. Nevertheless, the Lyapunov-based local analysis, combined with the extensive simulation validation, provides sufficient evidence of robust stability for the operating conditions considered in this study.
When system parameters are disturbed, fuzzy rules adjust the amplitude by limiting PID parameters to avoid closed-loop instability caused by sudden changes in parameters. Simulation results show that within the range of ±20% parameter disturbance, the system response remains asymptotically stable, and there is no divergence or continuous oscillation, indicating that the proposed control strategy has certain robust stability. As shown in
Table 3. The stability parameter disturbance response is shown in
Figure 9.
5. Experimental Verification
5.1. Implementation and Comparison of Fuzzy-PID in Proportional Control Valves
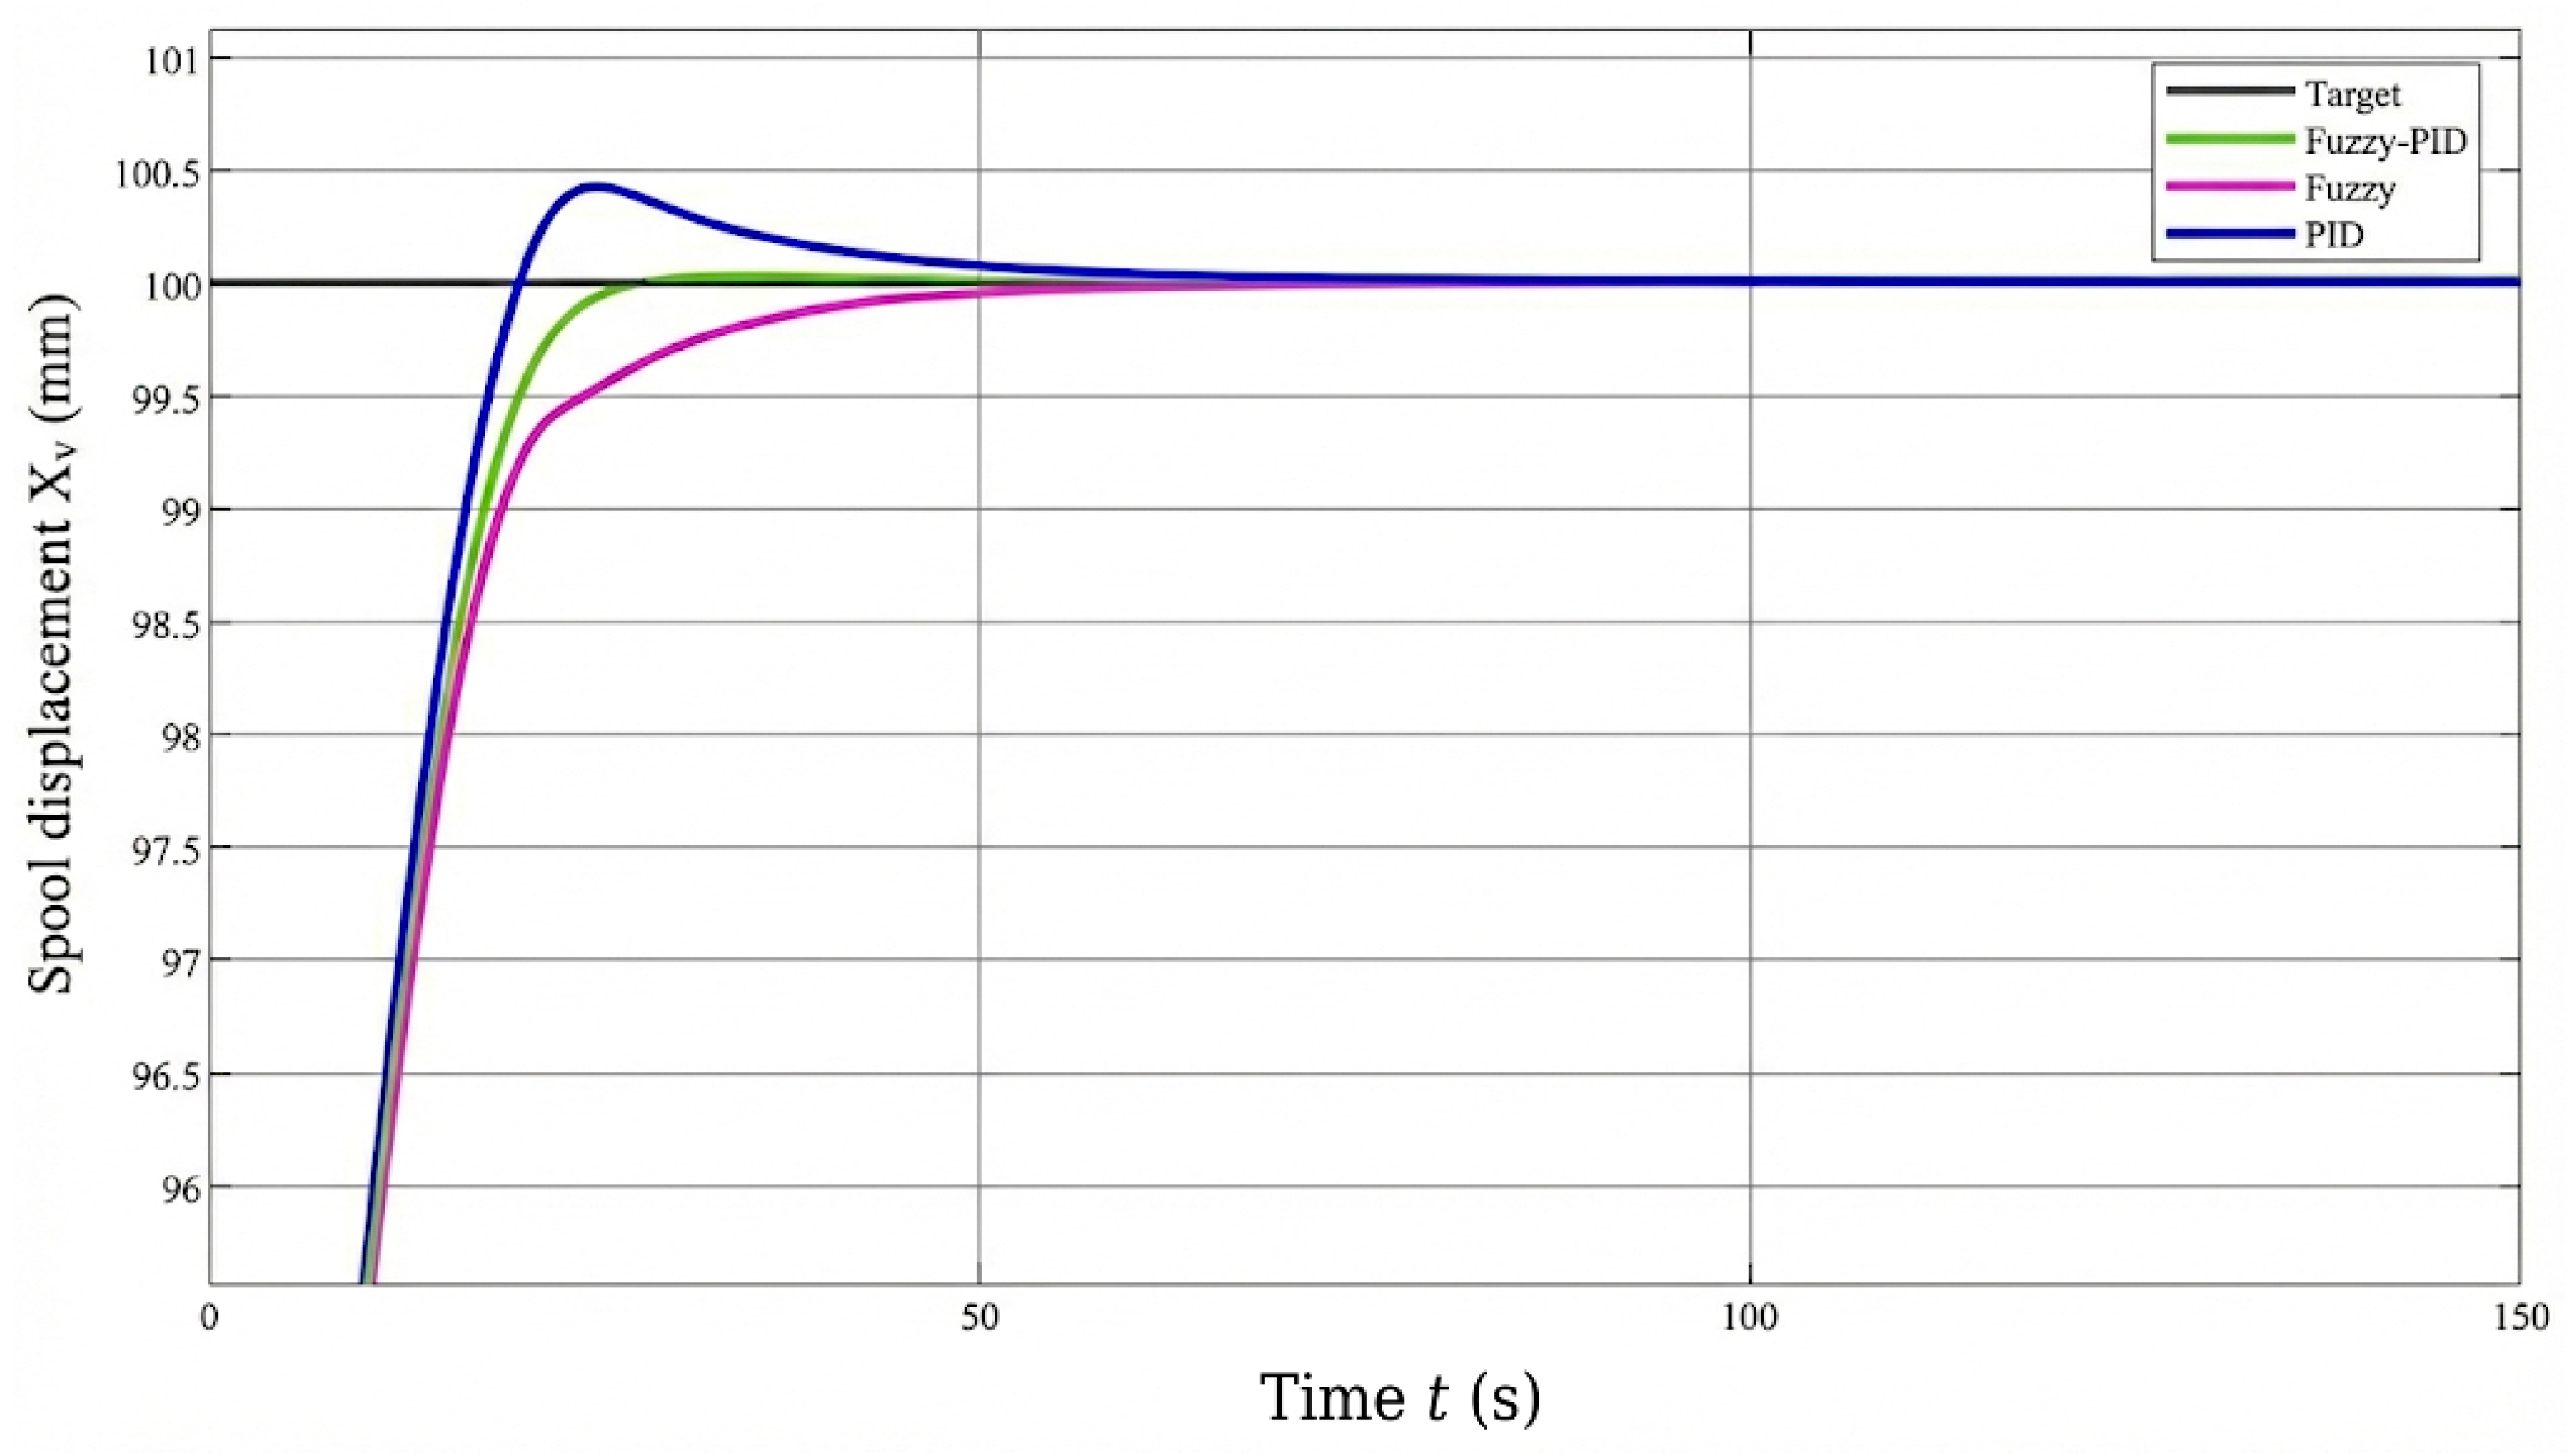
The present study validated the control performance of an electromagnetic pneumatic system. A comparison of the proposed method with traditional PID control and fuzzy control using Matlab R2023b software was conducted to demonstrate the superiority of the proposed method, as illustrated in
Figure 12. As depicted in the figure, both fuzzy PID control (green line) and fuzzy control (purple line) achieve the target value (black line) more rapidly than traditional PID control (blue line), indicating that fuzzy PID control possesses a faster response time. In contrast, traditional PID control (blue line) demonstrates significant overshoot before attaining the target value, the target value is exceeded prior to stabilization in both the fuzzy PID control (green line) and fuzzy control (purple line) models. However, the overshoot values are smaller in the former, suggesting that fuzzy PID control is more effective in reducing overshoot. Furthermore, the fuzzy PID control (green line) stabilizes rapidly upon reaching the target value and maintains stability with minimal fluctuations. In contrast, the traditional PID control (blue line) continues to exhibit slight fluctuations after stabilization. The fuzzy PID control (green line) demonstrates superior performance in maintaining stability when confronted with changes in system parameters or external disturbances. This phenomenon can be discerned by examining its capacity to sustain stability subsequent to attaining the target value. The fuzzy PID control (green line) demonstrates a reduced discrepancy between its output value and the target value after attaining the target value, signifying enhanced control precision. Furthermore, the fuzzy PID control (green line) exhibits a seamless transition process devoid of the oscillations evident in the conventional PID control (blue line), suggesting that fuzzy PID control facilitates more refined control performance.
In summary, electromagnetic pneumatic systems exhibit strong nonlinearity, rendering traditional fixed-parameter PID control ineffective for dynamic operating conditions. The integration of fuzzy control with PID control, a combination referred to as “fuzzy PID control,” offers a unique approach by combining the flexibility of fuzzy control with the stability of PID control. A high value enhances the system’s resistance to displacement errors, rendering it suitable for suppressing positioning errors caused by friction. Conversely, a low value prevents flow overshoot in high-pressure zones by adjusting to real-time offset the inertial forces of the cylinder piston, thereby suppressing high-frequency vibrations. This configuration offers several advantages, including enhanced responsiveness, reduced overshoot, improved stability, and enhanced control accuracy. The merits of fuzzy PID control become particularly evident in the context of electromagnetic control systems, where high precision and rapid response are paramount. A comprehensive experimental analysis reveals that the average overshoot of fuzzy PID is 4.2%, in comparison to 6.5% for traditional PID. This represents a 35% reduction, effectively mitigating flow overshoot during valve core startup. In the context of valve core sudden load change tests, resulting in a steady-state error that is lower than that of the traditional PID system. This outcome serves to demonstrate the adaptability of the fuzzy PID system in highly nonlinear scenarios.
5.2. Verification of Flow Estimation Accuracy of Proportional Valves in Noisy Environments
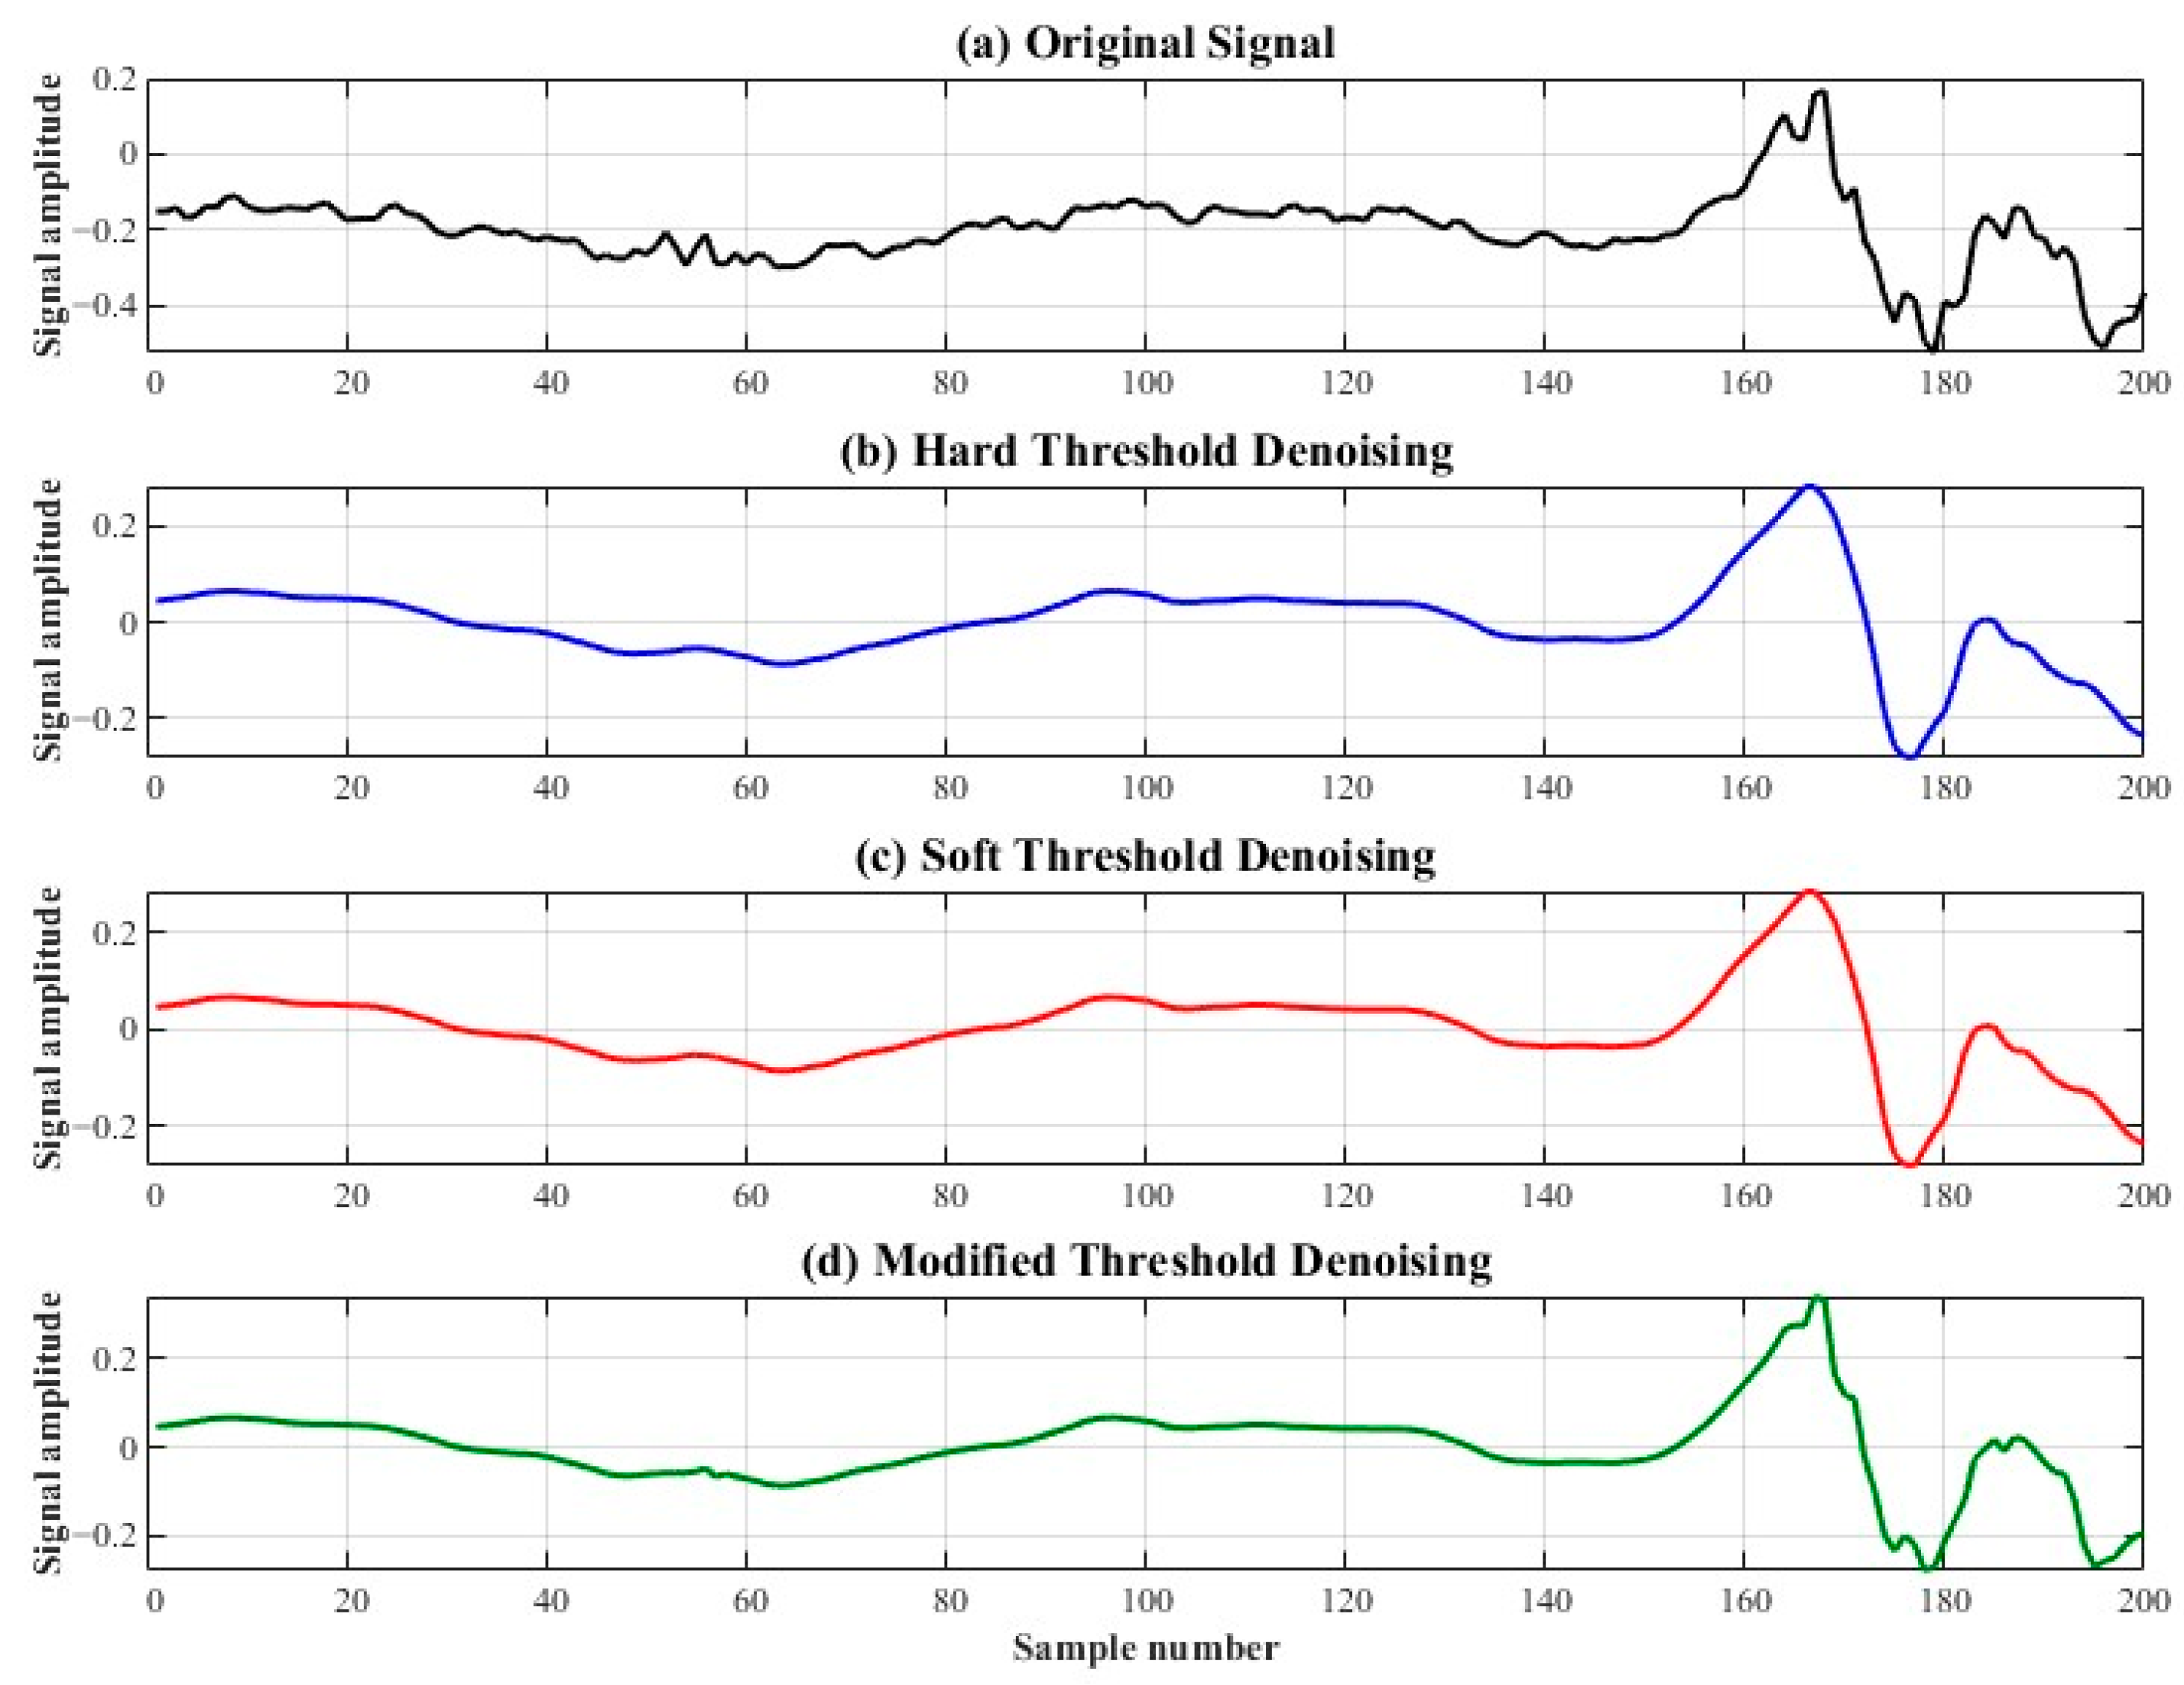
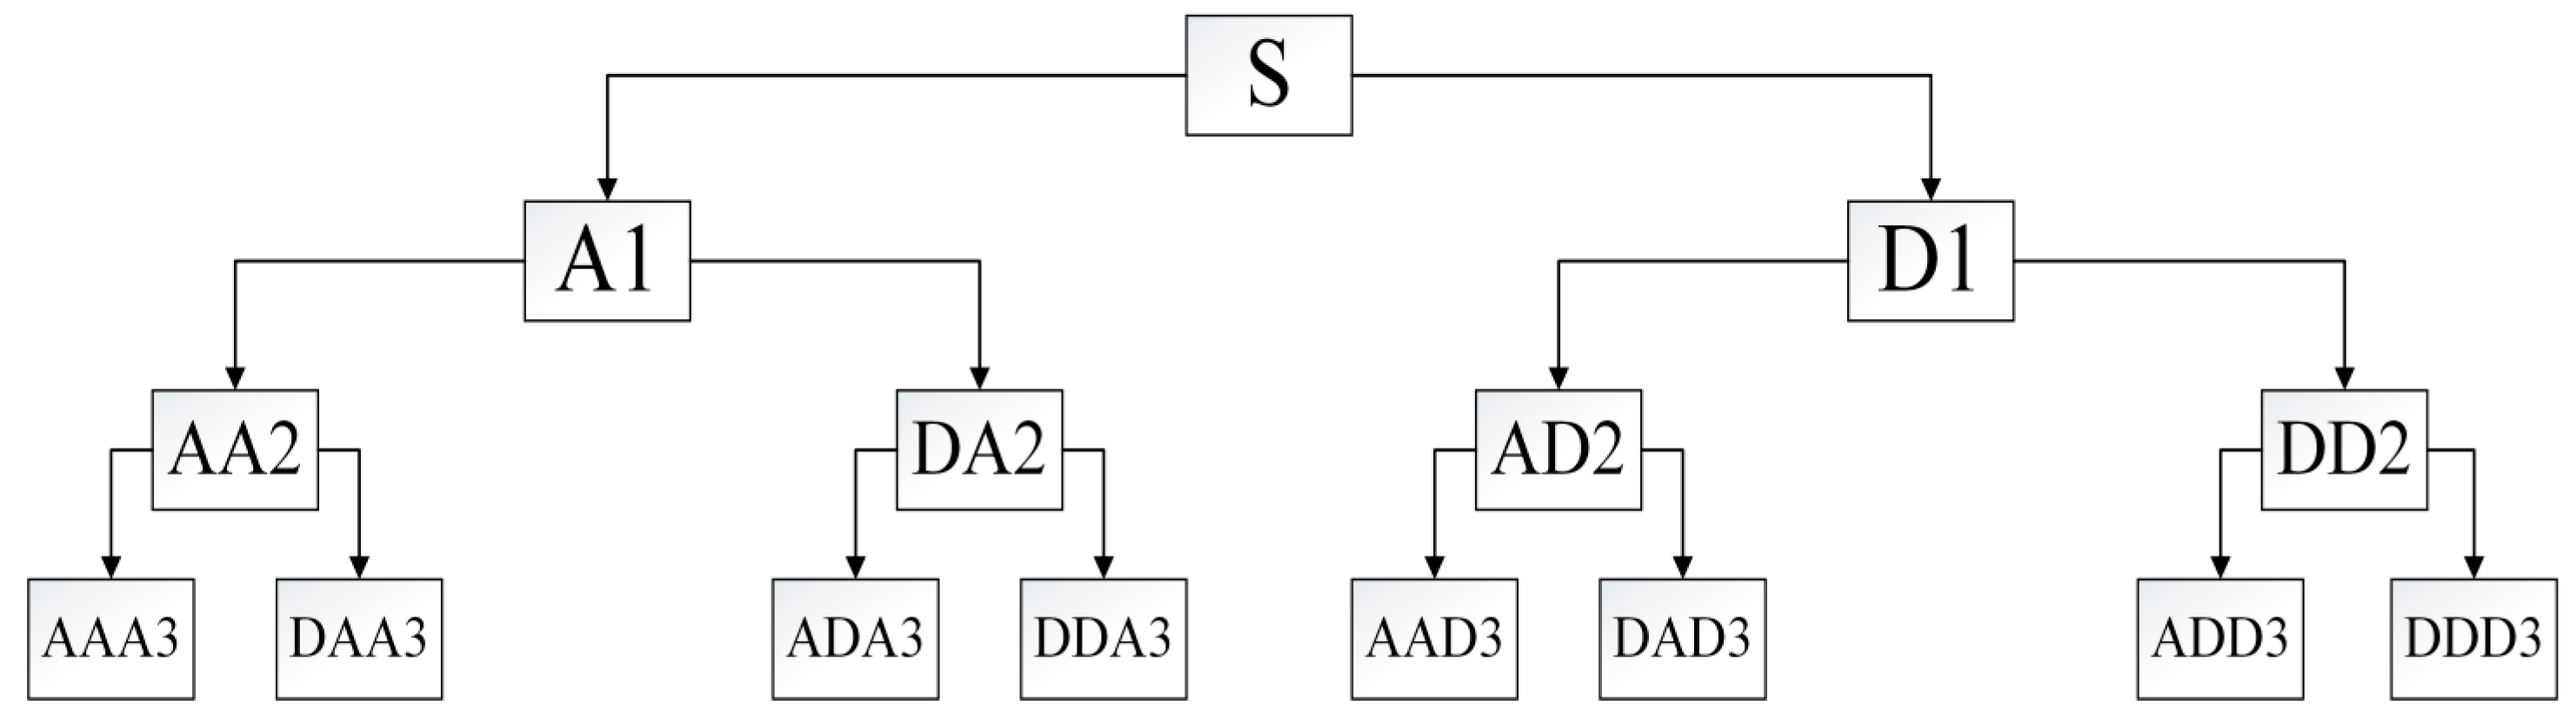
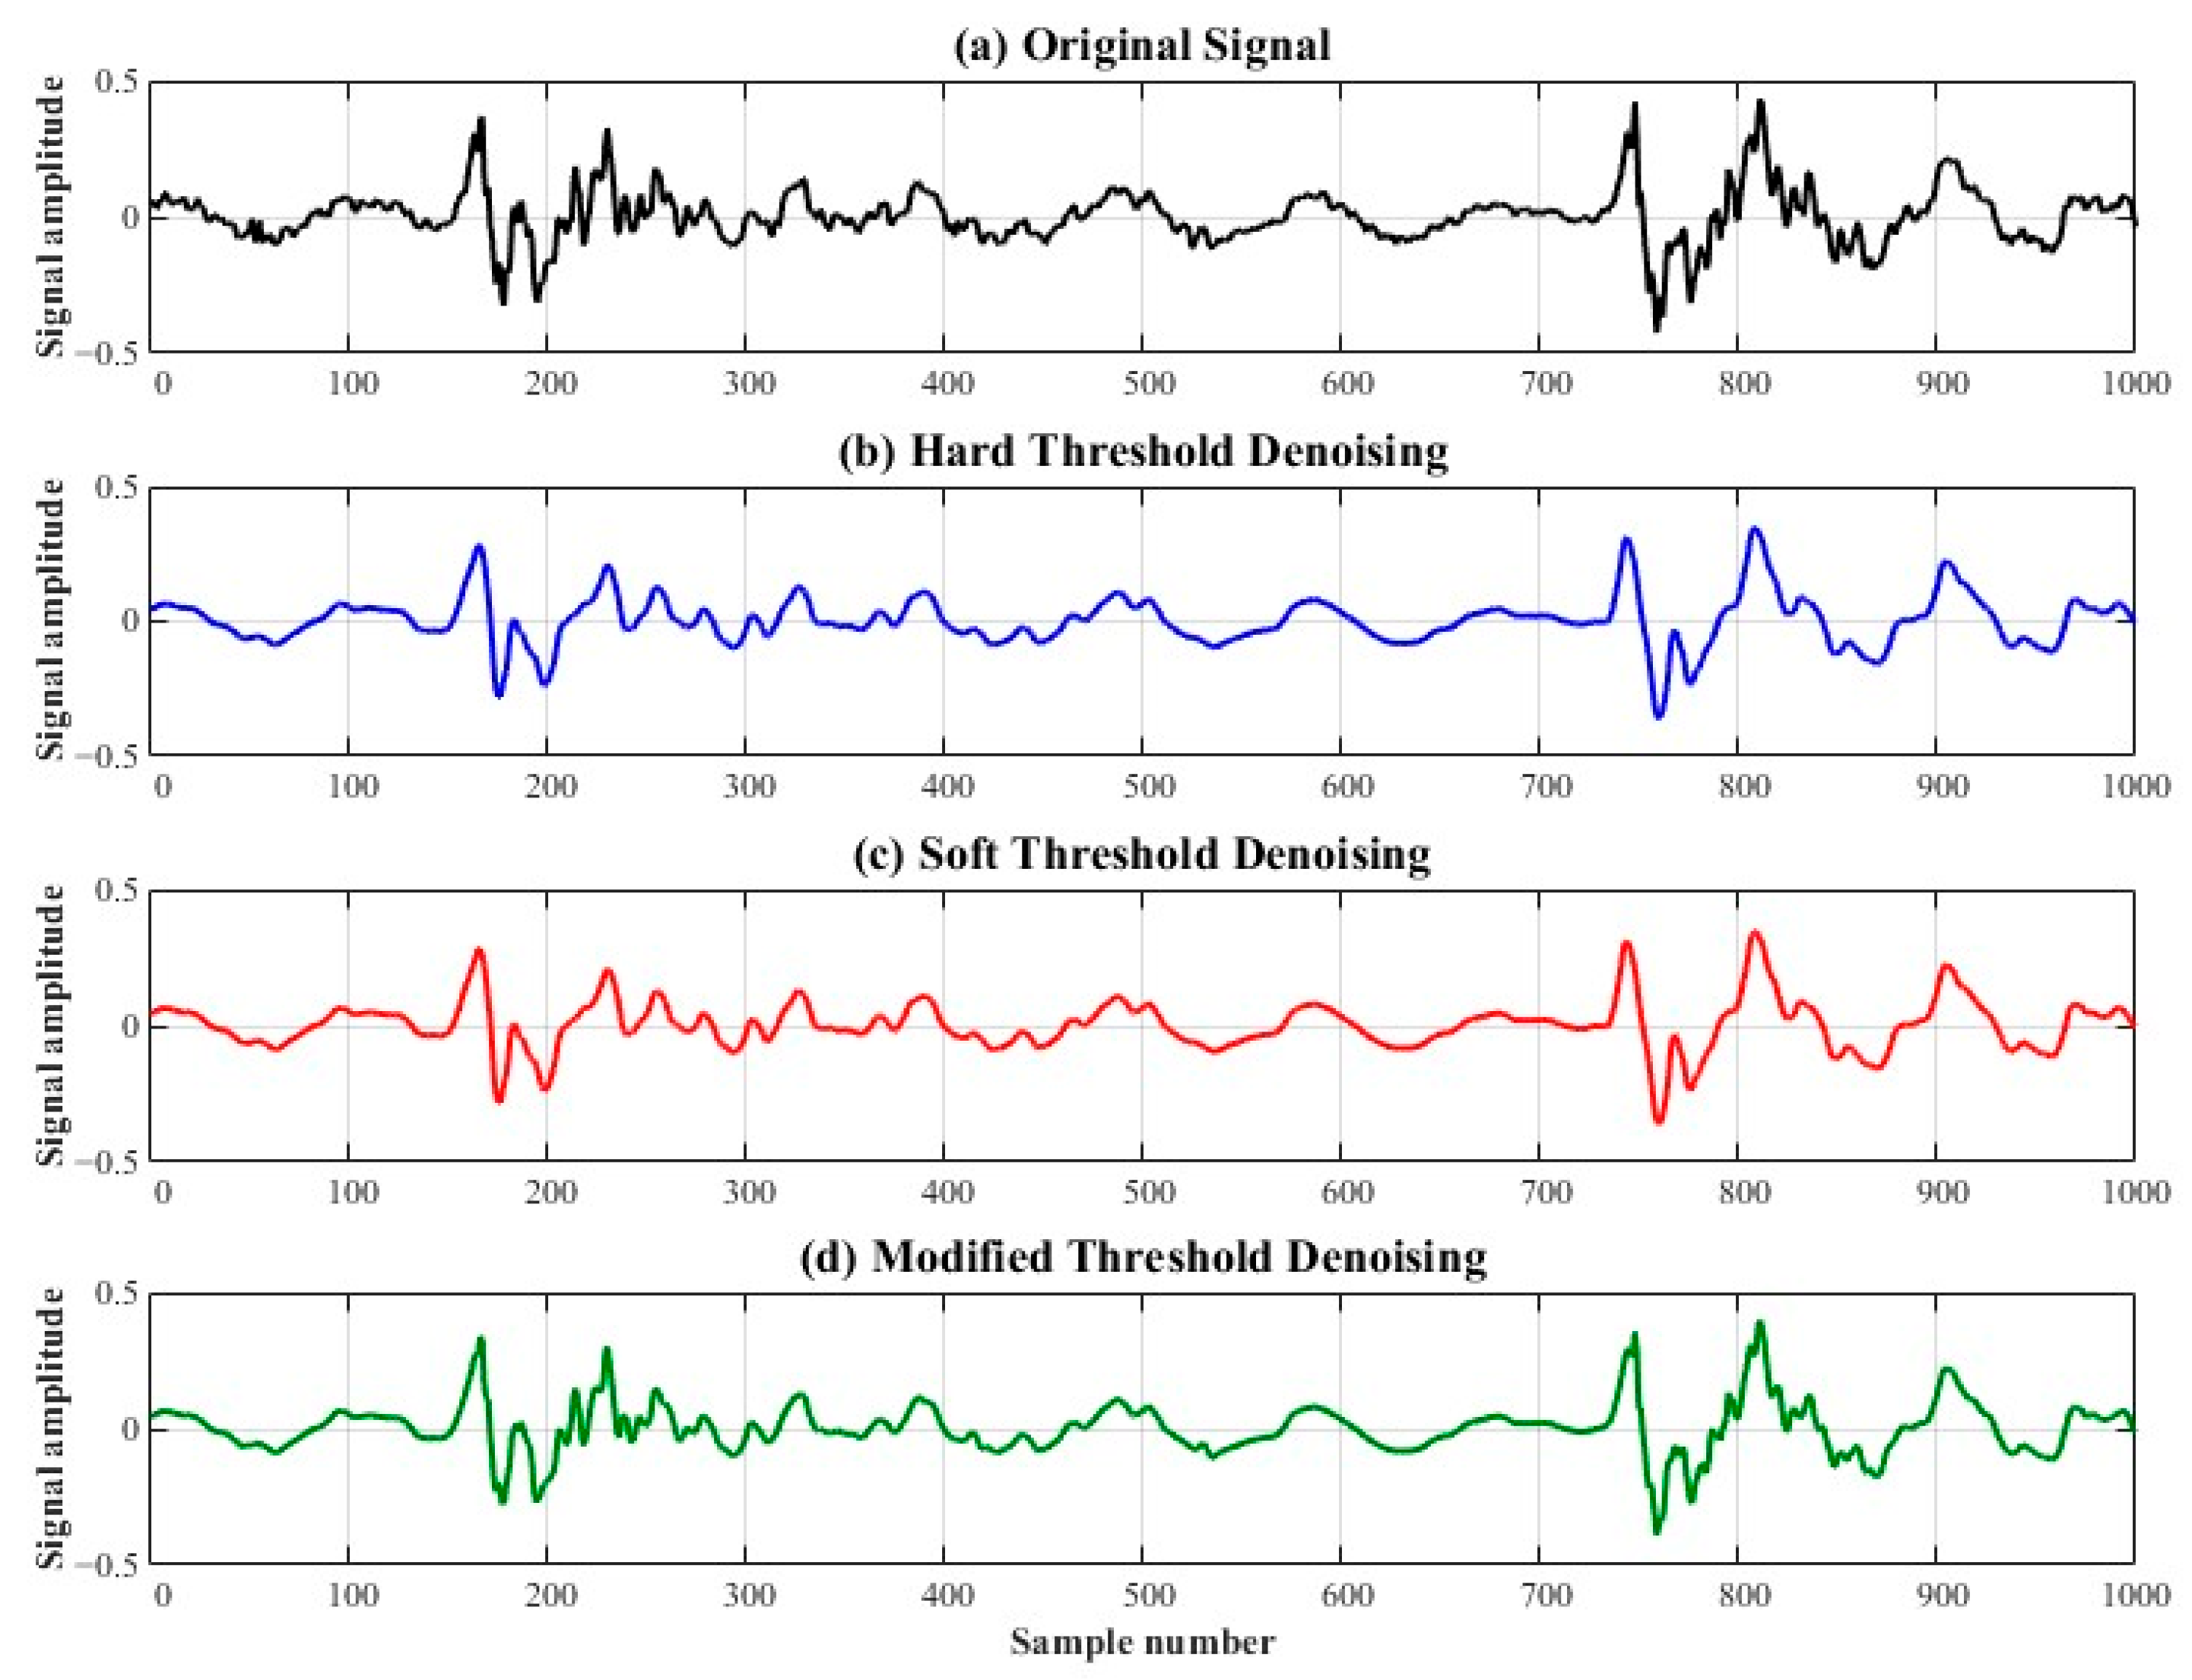
As shown in
Figure 13 and
Figure 14, The experimental design involved the implementation of conventional hard threshold denoising, soft threshold denoising, and enhanced denoising methodologies, employing 200 and 1000 signal points, respectively. The signal-to-noise ratio (SNR) and root mean square error (RMSE) were utilized as evaluation criteria. A higher signal-to-noise ratio (SNR) and lower root mean square error (RMSE) are indicative of superior denoising performance. The threshold determination method for both hard threshold and soft threshold is the minimum root mean square error (SURE). The threshold type is designated as the global threshold, and the wavelet basis function is the fourth-order Doubchey wavelet.
In order to facilitate a more intuitive and accurate comparison of the data results, the graphs of 1000 data points after noise reduction were compared.
The experimental results suggest that hard thresholding sets coefficients below a certain threshold to zero, while coefficients above the threshold remain unchanged. Consequently, specific components of the signal may become more uniform after the implementation of hard thresholding; However, this process can result in the loss of certain details, thereby inducing discontinuities. In contrast, traditional soft thresholding involves the subtraction of the threshold from all coefficients and the subsequent setting of the result to zero if it is negative. While this method reduces discontinuities compared to hard thresholding, it may cause some parts of the signal to be overly smoothed. The enhanced thresholding method has been shown to enhance the preservation of signal details while concomitantly reducing noise, particularly in complex signals. This approach has been demonstrated to achieve a superior balance between preserving signal details and reducing noise. According to the evaluation criteria, the SNR of the enhanced threshold processing on 200 datasets is 14.4925, and the RMSE is 0.0187544. When processing 1000 datasets, the SNR has been shown to improve from 9.08 dB to 14.98 dB, representing a 64.9% increase, while the RMSE has been shown to decrease from 0.035 to 0.017, representing a 49% reduction. As shown in
Table 5, A comparison of the improved threshold method with traditional hard threshold and soft threshold methods reveals a substantial enhancement in SNR and a notable reduction in RMSE. This outcome signifies a superior noise reduction performance for the improved threshold method.
To further validate the practical applicability of the proposed method, robustness tests under varying noise and load conditions were conducted. In order to be closer to the actual industrial environment, this paper introduces multiple noise intensity disturbance conditions based on the original uniform noise model to verify the robustness of the proposed method. Three noise levels are specifically set, corresponding to low signal-to-noise ratio, medium signal-to-noise ratio and high signal-to-noise ratio, respectively, and high-frequency electromagnetic noise and low-frequency pressure fluctuation noise are superimposed.
Experimental results show that the improved wavelet threshold method can maintain a high signal-to-noise ratio improvement effect under different noise intensities, verifying the applicability of the method in complex industrial noise environments. As shown in
Table 6.
5.3. Traffic Estimation Implementation
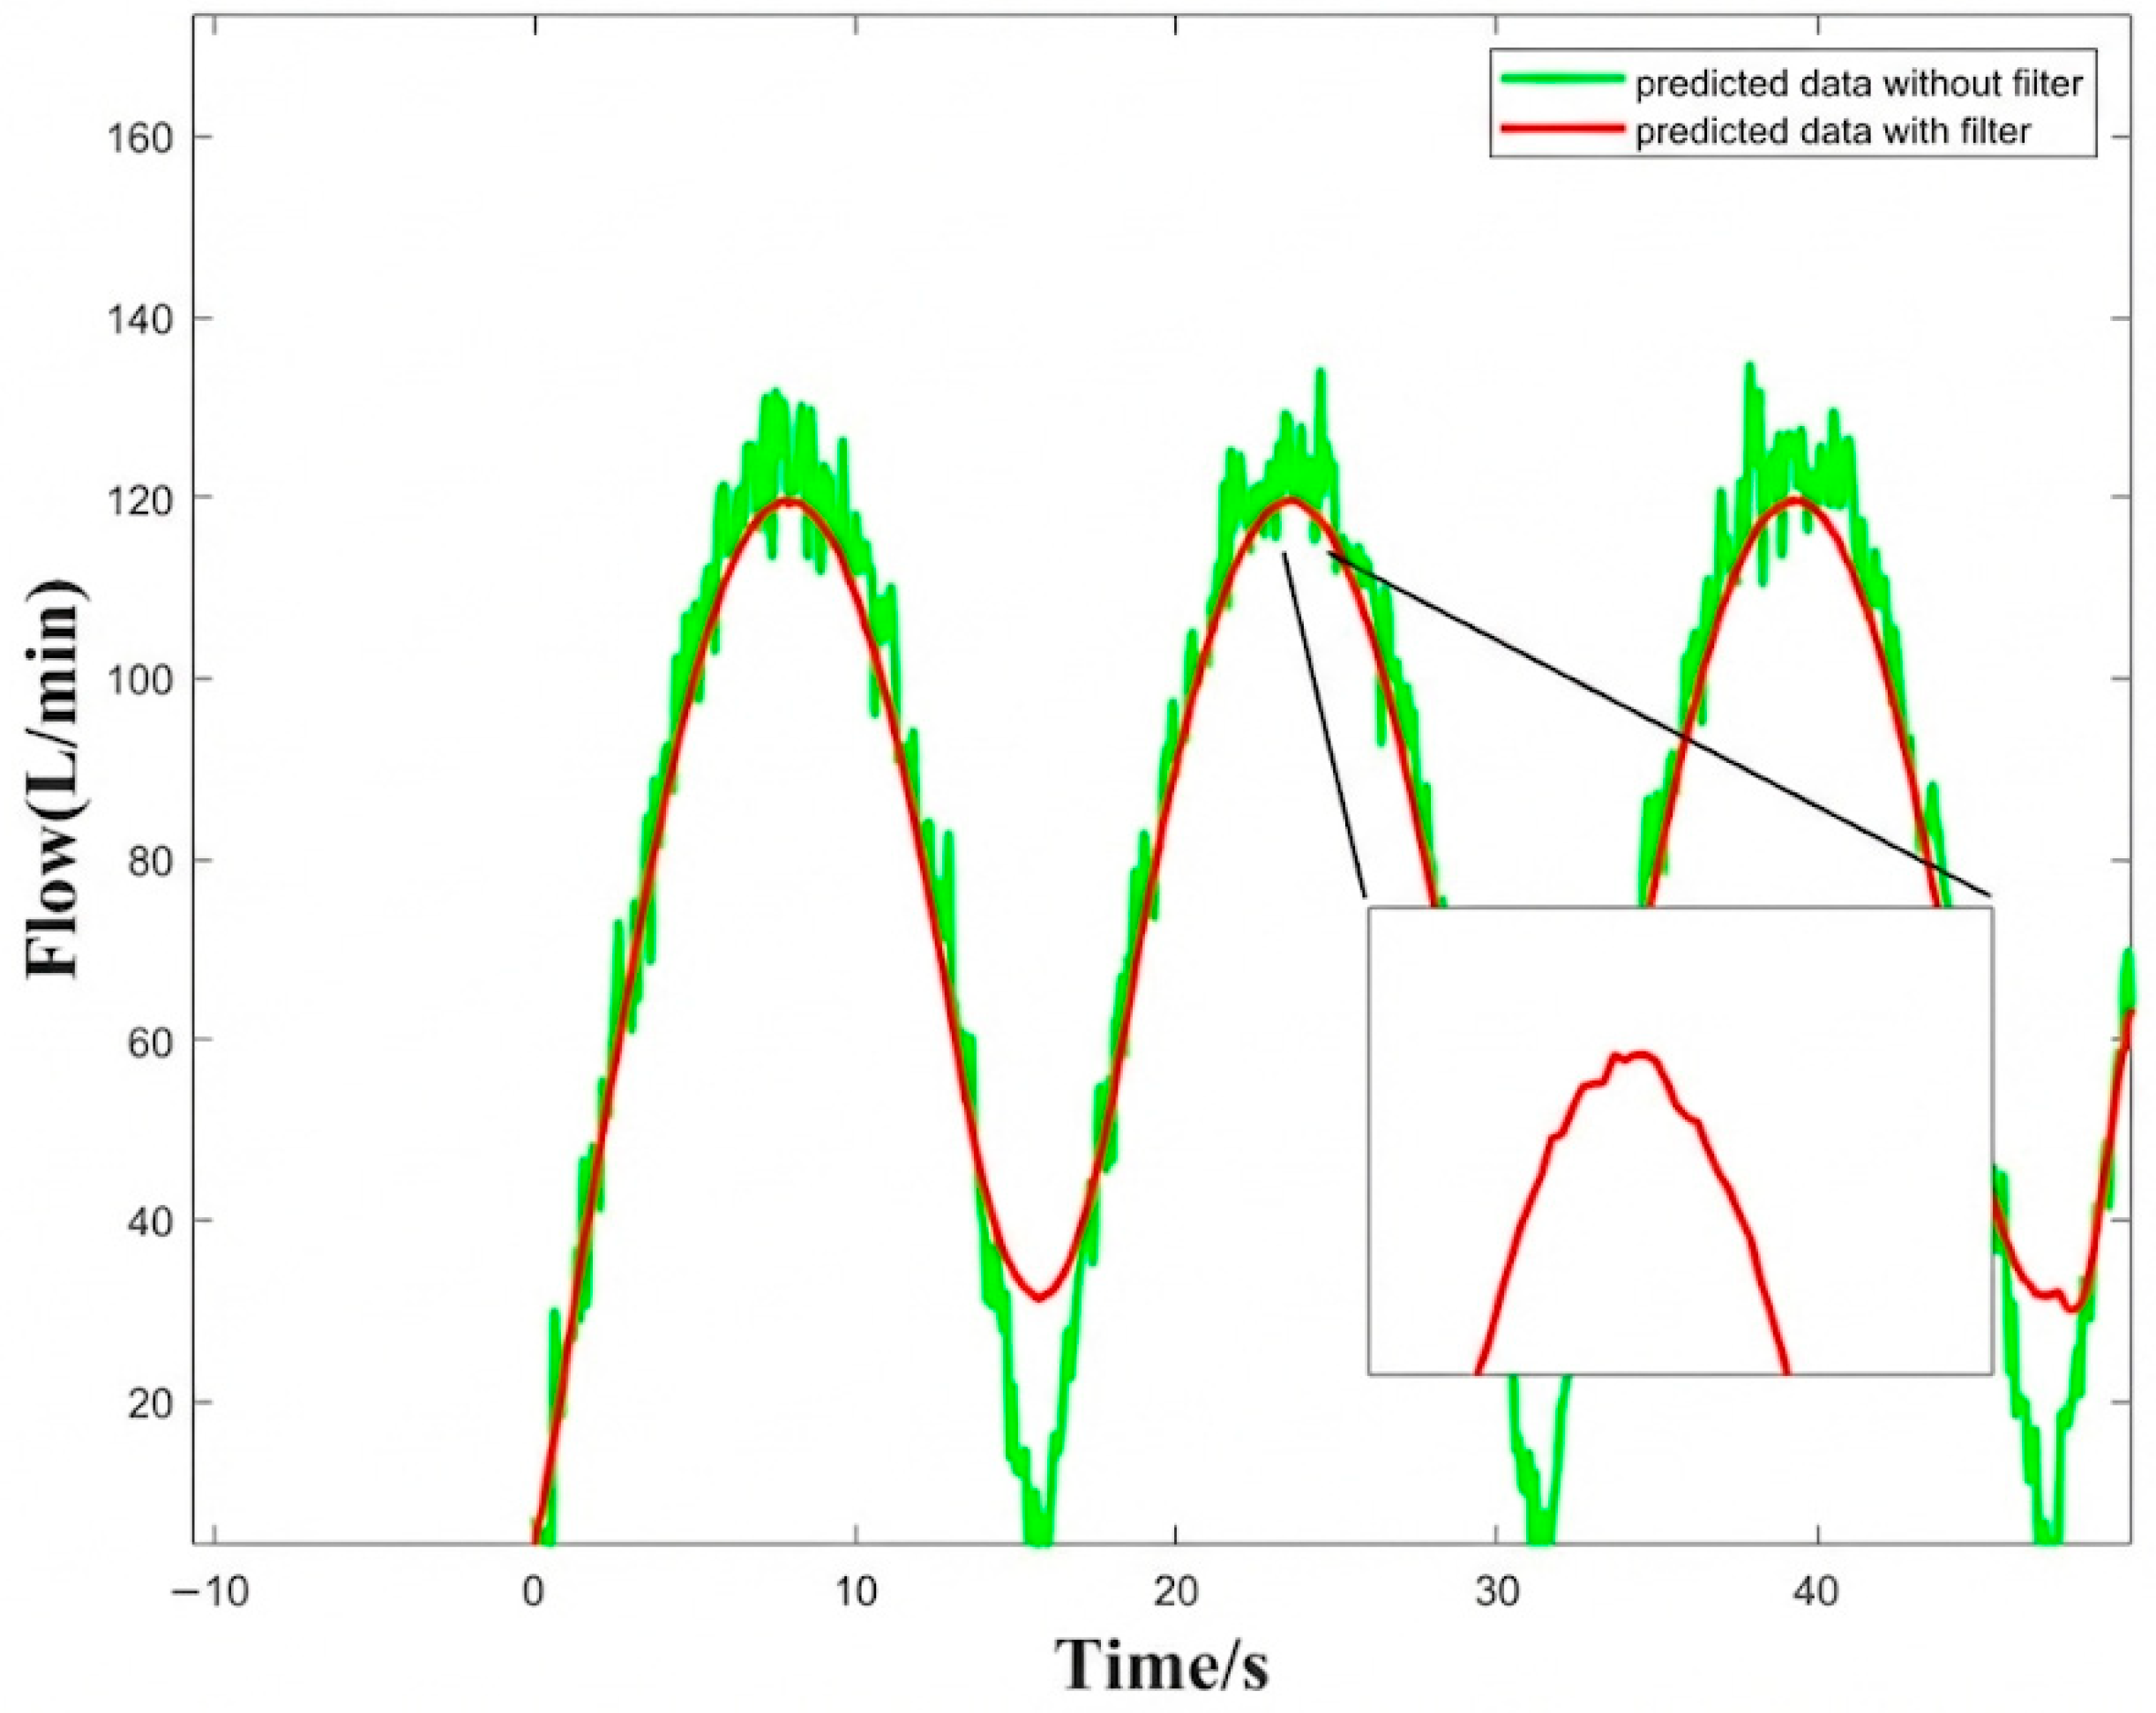
To make a comparison, a sine signal was used to demonstrate the difference between flow estimation based on the improved wavelet denoising method and flow estimation based on the original signal. The results are shown in
Figure 15. It can be observed that using filtered training data for model training and filtered test data for prediction yields signals with reduced noise information and smoother overall curves, resulting in a significant reduction in prediction error. In contrast, using the original data for model training and prediction introduces a large amount of noise into the prediction data. These interferences are caused by two factors: (1) the presence of noisy segments in the training data affects the model’s accuracy, and (2) using signals susceptible to noise interference during the testing phase, especially pressure signals, introduces high-frequency noise into the predicted flow signals. During the control process, the presence of high-frequency noise in feedback signals can cause system instability and affect control accuracy. Therefore, improving the wavelet denoising method can enhance the model’s accuracy and mitigate the impact of noise in the perceived signals on the predicted flow signals.
5.4. Comparison of Multi-Method Flow Inference Performance
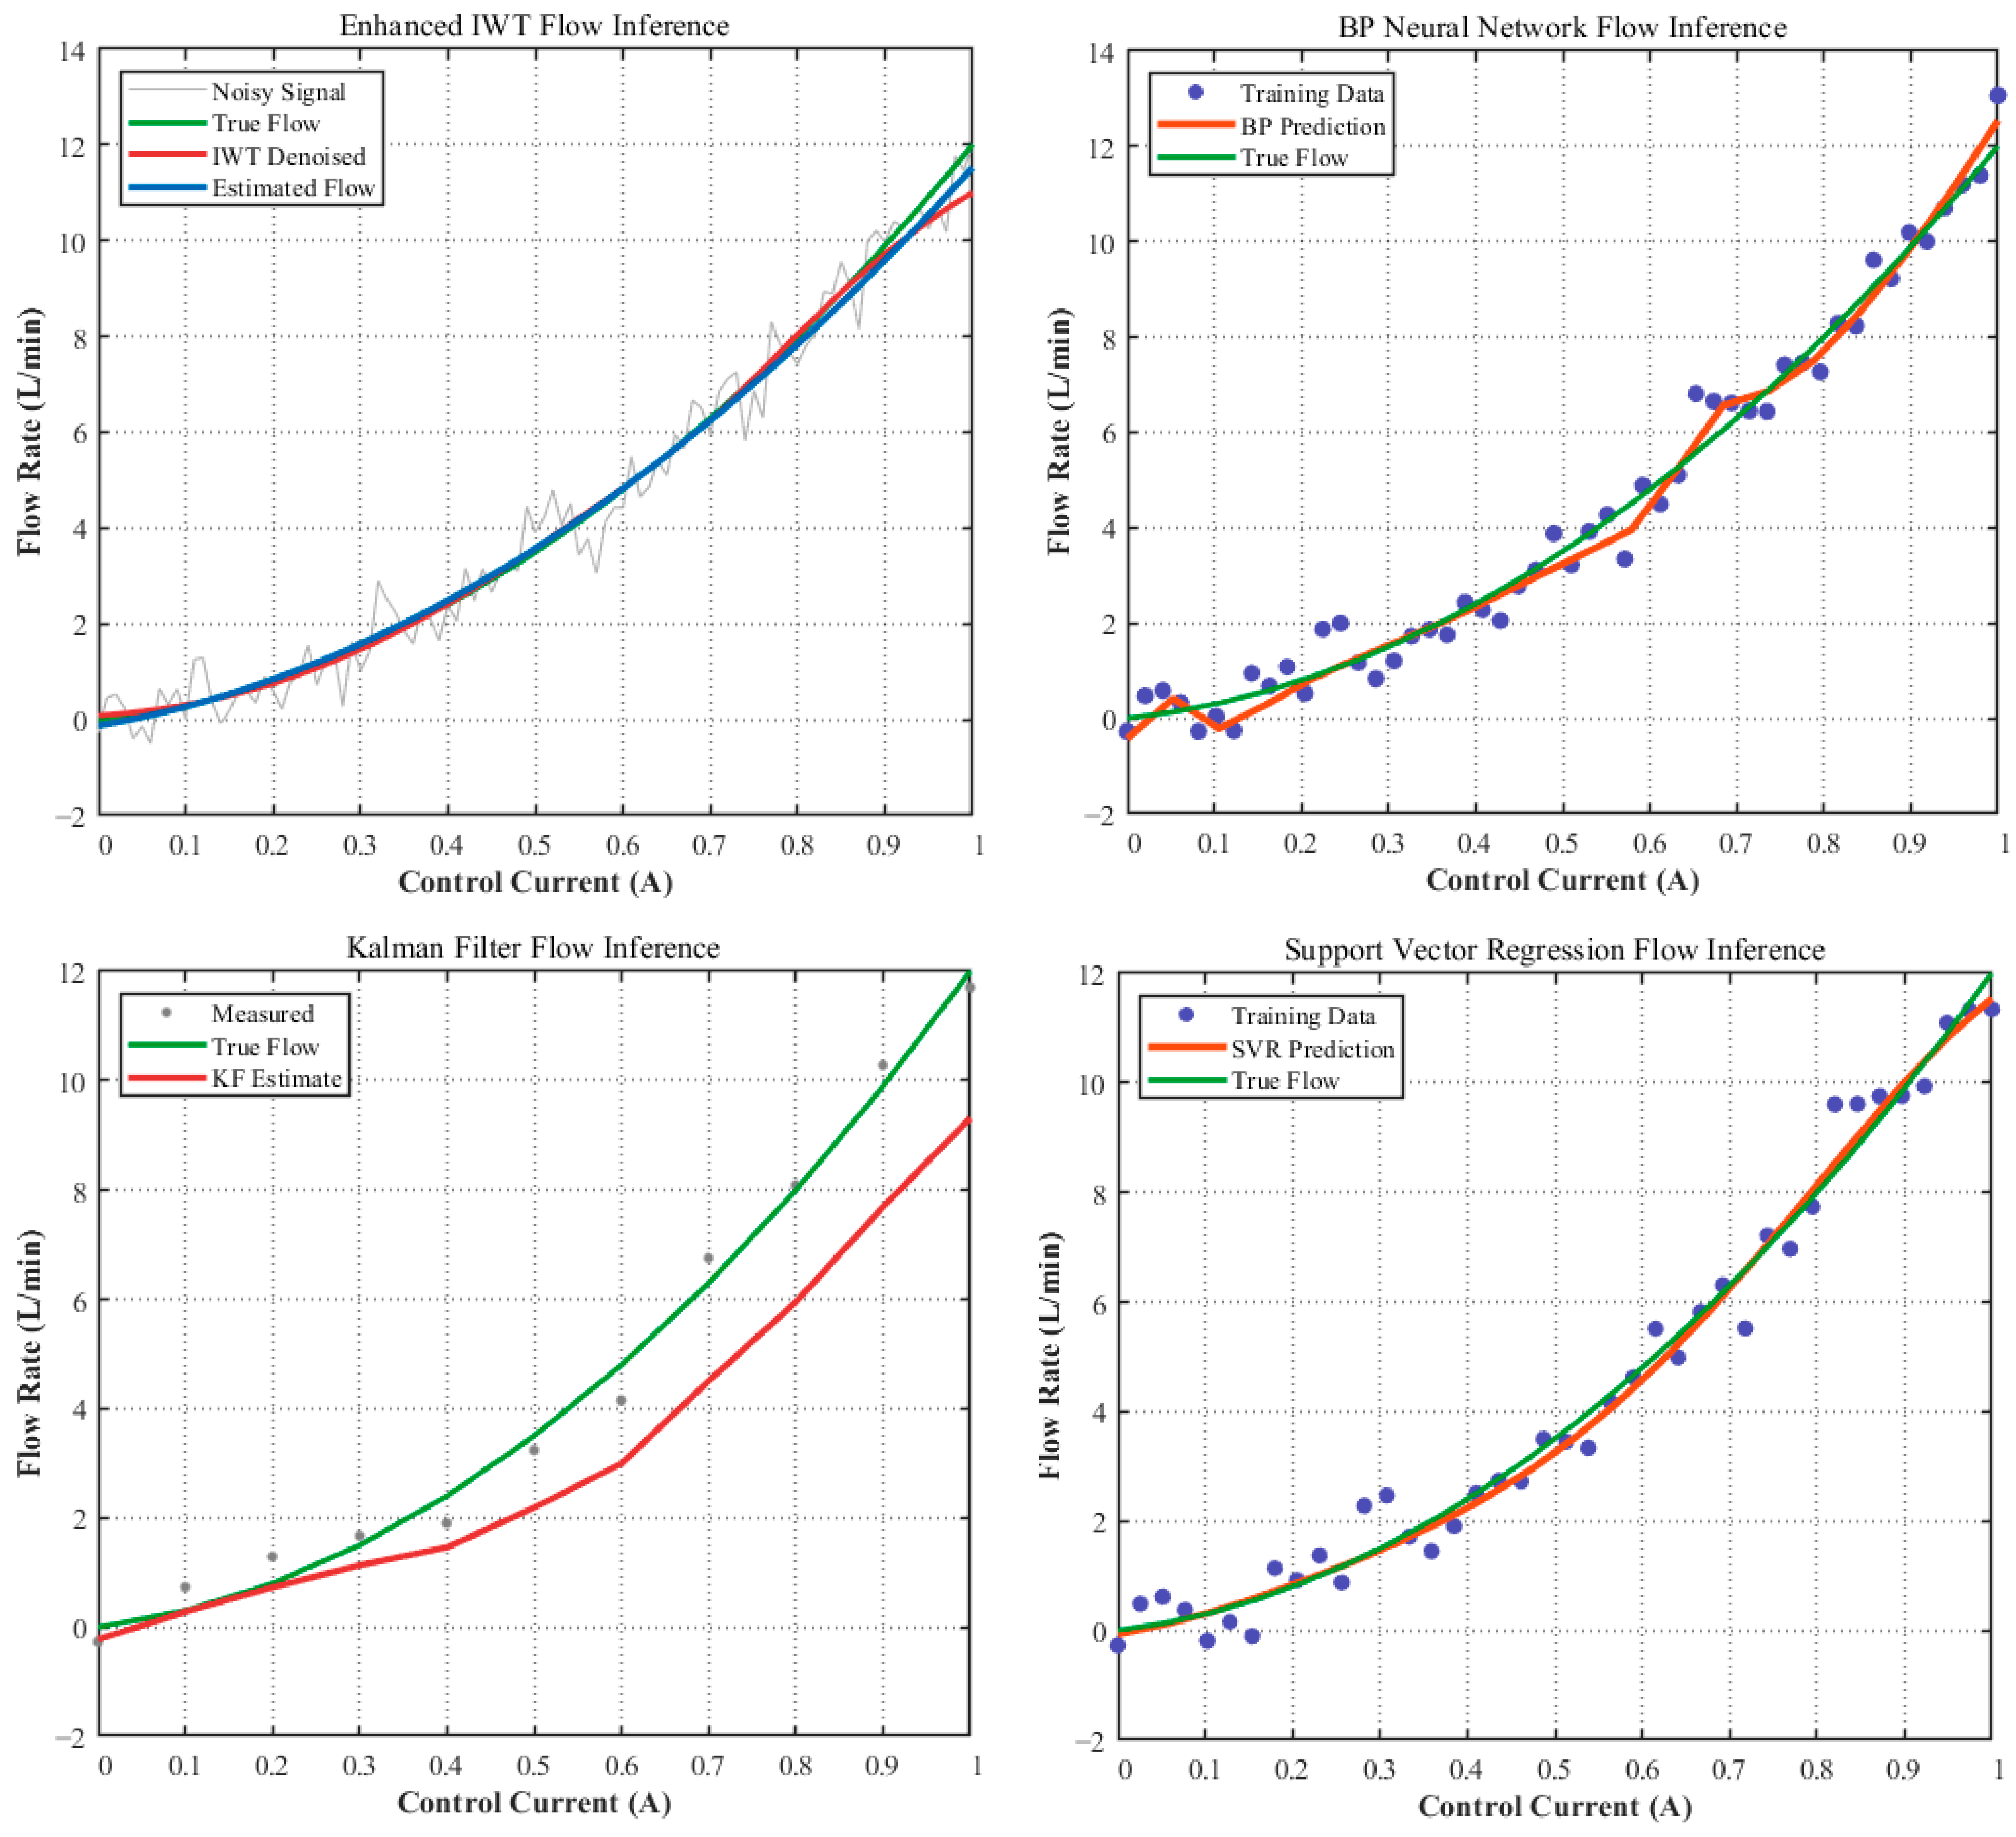
The objective of this section is to validate the superiority of improved wavelet denoising (IWT) in flow estimation. To this end, a comparative experiment is conducted in which IWT is compared with three mainstream methods: BP neural networks, Kalman filtering, and support vector regression (SVR). A strictly controlled comparison framework is adopted to ensure the fairness of the results. All methods utilize the same nonlinear system model, which is based on actual valve characteristic curves. The training set and test set utilize the same noise model, with 0.5 standard deviation of random noise added to simulate the Gaussian noise typically present in sensor measurements, superimposed on the real flow signal. A fixed random seed is employed to ensure noise consistency. The evaluation metrics are uniformly defined as SNR, RMSE, and computation time. To ensure the validity of the findings, all metrics were calculated using the same code to eliminate implementation differences. Furthermore, the current range of the test set was extended beyond that of the training set to rigorously validate the generalization capability of the methods. Furthermore, all experiments were conducted within the same software and hardware environment to eliminate platform dependency. The flow estimation curves of the multi-methods under the same test signals are shown in
Figure 16, and the evaluation metrics are presented in
Table 7.
In summary, BP neural networks, as a classic data-driven method based on gradient descent for approximating nonlinear functions, are suitable for the complex nonlinear systems of pneumatic electromagnetic proportional valves. Following the training process, the system demonstrates the capacity to execute computations expeditiously, exhibiting commendable real-time performance. However, these models are heavily reliant on substantial training data, and the training process may exhibit slow convergence, rendering them susceptible to noise in the training set. Kalman filtering is a dynamic estimation method based on state-space models, making it suitable for flow estimation in linear systems and noisy environments. It exhibits low computational complexity but is contingent upon an accurate system model and performs inadequately in highly nonlinear pneumatic systems. Support vector regression is a nonlinear regression method based on the principle of minimization. The method demonstrates robustness to small sample data and exhibits good generalization ability. However, it is characterized by complex parameter tuning, high computational complexity, extended training time, and insufficient robustness in practical applications. The improved wavelet denoising method proposed in this paper employs adaptive threshold denoising to effectively remove noise while preserving the key features of the flow signal, thereby improving signal fidelity. The model is integrated with least-squares regression for flow estimation, a process that enhances estimation accuracy and prevents overfitting, while demonstrating robust noise resistance. Furthermore, wavelet analysis has the capacity to process nonlinear and non-stationary signals, rendering it well-suited for the intricate flow characteristics exhibited by nonlinear pneumatic-electromagnetic proportional valve systems.
The experimental data demonstrate that IWT exhibits significant superiority in key performance metrics. Specifically, its signal-to-noise ratio (SNR = 22.707 dB) is 1.29 dB higher than that of the second-best method, support vector regression (SVR, 21.421 dB). IWT also outperforms the Kalman filter (KF) in denoising accuracy, with its SNR (22.707 dB) being 2.059 dB higher than that of KF (20.648 dB). The root mean square error (RMSE) of the IWT model is 0.413, the lowest among all tested algorithms—approximately 61.2% lower than the RMSE of the BP neural network (BPNN, 1.063) and 14.8% lower than that of SVR (0.485), indicating superior estimation accuracy. Furthermore, IWT achieves excellent computational efficiency (2.303 ms) while maintaining high precision: it is significantly faster than BPNN (12.819 ms) and SVR (6.457 ms), and although it is slightly slower than KF (0.028 ms), it far surpasses KF in denoising accuracy. Enhanced wavelet denoising employs an adaptive threshold function and a hierarchical denoising strategy, thereby effectively mitigating noise while preserving signal nuances. This approach eliminates the need for substantial training data and adapts to nonlinear systems, thereby overcoming the underfitting tendency of BP neural networks in scenarios with limited training data. The proposed approach circumvents the limitations of Kalman filtering under linear assumptions, which are associated with a model mismatch. Additionally, it evades the computational bottlenecks that are prevalent in SVR implementations during large-scale hyperparameter optimization. This solution offers high precision and low latency flow estimation in complex industrial scenarios.




 ,