


Abstract
Offshore cranes are widely used in important fields such as wind power construction and ship replenishment. However, large payloads such as wind turbine blades are hoisted by multiple steel wire ropes, which makes it difficult to directly control their movements; that is, the number of input degrees of freedom is less than that of the output degrees of freedom. In addition, compared with land cranes, offshore cranes are inevitably affected by waves, wind, etc. The transition from a fixed base to a dynamic base brings severe challenges to their oscillation suppression and precise positioning. At the same time, to improve operational efficiency, the hoisting operation of offshore cranes usually adopts velocity input control patterns that fit the habits of manual operation, and most of them are in the form of dual-axis linkage for pitch and hoisting. Therefore, this paper proposes a fast terminal sliding mode control method for double-pendulum offshore cranes with distributed-mass payloads (DMPs). First, a nonlinear dynamic model of offshore cranes considering DMPs is established, and a dynamic model based on acceleration input control patterns is acquired. Based on this, considering the variation in hoisting rope lengths, a novel adaptive control method is proposed. Finally, simulation results verify the effectiveness of the proposed method, and the robustness of the proposed method to DMP mass parameter uncertainty and disturbances is demonstrated.
1. Introduction
As important equipment for transporting operations in offshore environments, offshore cranes [1,2,3] are widely used in important areas, such as payload transportation between ships [4], offshore replenishment [5], engineering construction [6], and the deployment and recovery of underwater operating equipment [7]. However, complex marine environments pose significant challenges to the efficient and safe control of offshore cranes [8,9]. Specifically, compared with land cranes, offshore cranes inevitably experience pitch, yaw, and roll motions, and are extremely susceptible to external disturbances such as wind at sea, which will make it more difficult to suppress the oscillations of underactuated payloads [10,11]. In addition, large payloads such as wind turbine blades usually require multiple wire ropes for hoisting, which leads to two severe challenges in the control of offshore cranes: (1) Compared with the point-mass hoisting patterns, the non-negligible DMP volume and shape make the dynamic characteristics of offshore cranes more complicated. (2) Offshore cranes cannot directly control the DMP states; that is, the number of input degrees of freedom is less than that of the output degrees of freedom.
In recent years, studies on offshore crane control have received widespread attention, and some excellent control methods have been proposed [12,13,14]. Specifically, trajectory planning methods are widely utilized for the oscillation suppression of offshore cranes. For example, a generalized trajectory modification strategy is proposed, only requiring the measurement of the ship’s roll and pitch angles [15]. In addition, some advanced control methods are proposed to deal with problems such as disturbances for achieving better control performance, including hierarchical sliding mode controllers [16], fuzzy controllers [17,18], and nonlinear partially saturated controllers [19]. For instance, to achieve the oscillation suppression and precise positioning of underwater payloads, a coupling characteristic indicator-based nonlinear control method is proposed [20]. Additionally, the patterns of rotating/translating and hoisting simultaneously on offshore cranes are widely adopted to improve their working efficiency. For example, Sun et al. propose a trajectory tracking strategy based on proportional derivative (PD) controllers for offshore cranes [21].
In addition, in recent years, the requirements for safe and efficient hoisting tasks of large payloads such as wind turbine blades, drilling platform modules, large storage tanks, rocket segments, etc., have become increasingly urgent, and control studies have begun to attract attention, and scholars have proposed some solutions [22]. For example, in [23], the dynamic characteristics of double-pendulum overhead cranes with DMPs are analyzed. Meanwhile, Huang et al. propose a command smoothing method to suppress the complex oscillations of DMPs [24]. Further, the proposed method is applied to tower cranes with DMPs for dealing with the coupled oscillations among jib deflection, DMP swing, and DMP twisting [25]. Also, a model-free deep reinforcement learning-based trajectory planning method is designed for triple-pendulum overhead cranes with DMPs [26]. Additionally, some feedback methods are proposed for cranes with DMPs. An improved adaptive control method is proposed for overhead cranes with DMPs, and the uncertainties are effectively compensated by means of an improved update law [27].
Existing studies focus on point-mass single-pendulum and double-pendulum hoisting patterns, and some studies have considered DMP hoisting patterns, but mainly for overhead cranes and tower cranes. Therefore, this paper proposes a fast terminal sliding mode control method for offshore cranes with DMPs. First, a nonlinear dynamic model of double-pendulum offshore cranes is established. Subsequently, considering the variation in hoisting rope lengths and external disturbances, a novel adaptive control method based on acceleration input control patterns is designed, and the effectiveness of the proposed method is verified through simulations. The main contributions of this paper are as follows:
- (1)
- Nonlinear dynamic models of double-pendulum offshore cranes considering DMPs and variable hoisting rope lengths are established.
- (2)
- Based on acceleration input control patterns, a novel adaptive control method is proposed to suppress DMP oscillations and accurately position.
- (3)
- Simulation results demonstrate the robustness of the proposed method to time-varying rope length, external disturbances, and DMP mass uncertainty.
The main contents of this paper are as follows: The nonlinear dynamic model of double-pendulum offshore cranes considering DMPs is established in Section 2. Section 3 proposes a novel adaptive control method considering variable hoisting rope lengths. In Section 4, the effectiveness of the proposed method is verified through simulations. Section 5 concludes this paper.
2. Problem Statement
To ensure safety, offshore cranes usually use pitching and hoisting operations. For example, in narrow waterways, harbors, or during the maintenance of large bridges and installation of offshore wind turbines, pitching and hoisting operations can prevent the DMP from colliding with other large structures around it. In addition, during the DMP hoisting, rotation operations may cause the center of gravity of DMPs to shift and become unstable, or they may easily collide with the surrounding environment during rotation. Therefore, this paper mainly considers pitching and hoisting to suppress the swing of DMPs.
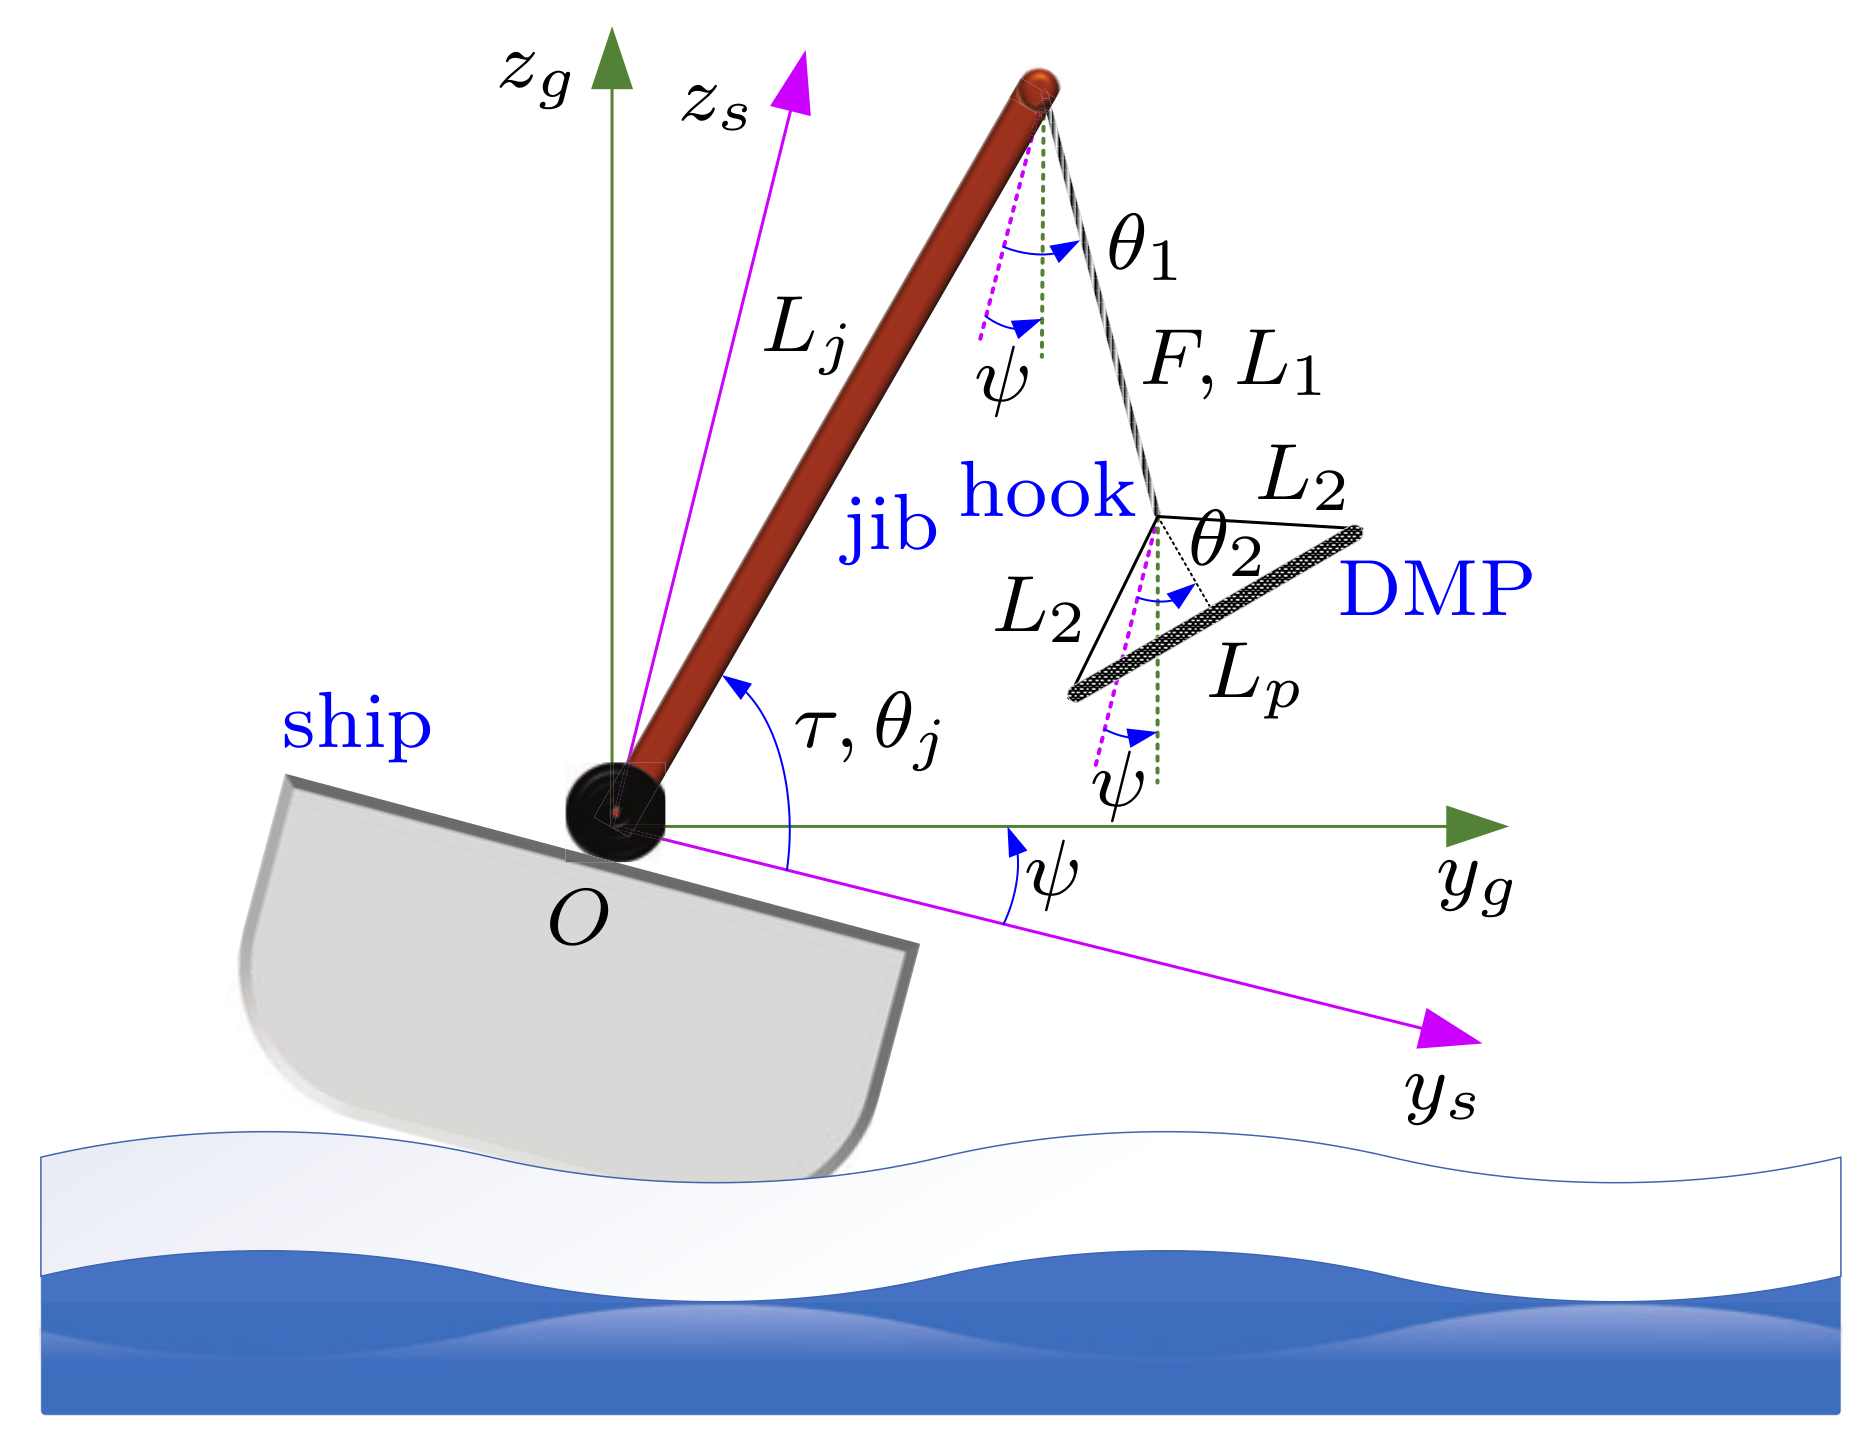
Figure 1 shows the model of a double-pendulum offshore crane with a DMP and variable rope lengths, where is the earth coordinates and is the ship coordinates. represents the angle between the earth coordinates and the ship coordinates, which is mainly caused by the sea waves. Without loss of generality, it is assumed that the center of gravity of the ship and the rotation axis of the offshore crane coincide, since the waves mainly cause the rotation of the ship around its center of gravity. The masses of the jib, hook, and DMP are , , and , respectively. The lengths of the jib, hoisting rope, rigging rope, and DMPs are denoted as , , , and , respectively. , , and are the jib luffing angles, hook swing angles, and DMP swing angles, respectively. represents the jib driving torque, and F represents the driving force of the hoisting mechanism. Further, defining , , and , the positions of the hook and DMP can be expressed as
where , are the moment of inertia for jibs and DMPs, respectively.
Figure 1.
Model of double-pendulum offshore cranes with DMPs.
Furthermore, the kinetic energy and potential energy of the jib, hook, and DMP can be calculated, respectively,
where g represents the gravitational constant.
Based on Lagrange’s methods, the dynamics of double-pendulum offshore cranes with DMPs are expressed as follows:
Further, to facilitate the subsequent analysis, (3)–(6) are rewritten as
where denotes the state vector, is the control input vector, , , , are the inertia matrix, the centripetal–Coriolis matrix, and the gravity vector, respectively. Specifically, is defined as
where
Additionally, is expressed as
where
Meanwhile, is expressed as
Additionally, we can verify that is positive definite and satisfies the following equation:
i.e., is the skew-symmetric matrix.
According to (3)–(6), it can be seen that control inputs can choose force/torque or acceleration/velocity/displacement. At the same time, considering that industrial offshore cranes are widely actuated by inverters, the acceleration pattern is closer to workers’ operating habits, so this paper chooses acceleration as a control input; i.e., (5) and (6) are chosen in this paper. Before controller design, the dynamic model is further transformed. First, (7) can be divided into an actuated system and an underactuated system, expressed as follows:
where and Further, in practical offshore cranes, is always positive and satisfies . is a positive definite matrix. Further, (13) is transformed into a dynamic model based on acceleration input control patterns as
where and
As seen from (14), only two inputs of and are available to actuate the four states of and to track the desired position. is utilized for the control of and , while is chosen to control ; that is, the dynamics are divided into four subsystems: the jib, hook, DMP, and hoisting mechanism. Based on this, the states are defined as , and the dynamics of double-pendulum offshore cranes (13) can be transformed as
where , , and and are the disturbances.
Considering that the control objective of offshore cranes is to adjust the DMP position to a pre-set position in earth coordinates, the desired position of DMPs in earth coordinates can be acquired as
where , and denote the desired jib luffing angles, the desired hoisting rope lengths, the desired hook swing angles, and the desired DMP swing angles, respectively.
Further, to effectively suppress DMP oscillations under the influence of offshore crane roll, the desired positions of the hook and DMP are chosen as
Therefore, defining t as the operating time of the offshore crane, the control objective can be concluded as
3. Control Method Design
In this section, a novel adaptive controller is designed for offshore cranes with DMPs. First, the tracking errors are defined as follows:
By taking the first- and second-order differentials of (23), substituting the dynamic model (15)–(18) into the resulting equations, and then performing some mathematical manipulation, the following equations can be calculated as
Furthermore, to deal with the coupling relationship between the jib, hook, and DMP, a hierarchical sliding mode control method is introduced for controller design. First, three fast terminal sliding surfaces are proposed for the subsystems of the jib, hook, and DMP, respectively, as follows:
where , and are all positive odd integers, which satisfies that .
When disturbances are not considered, the following equivalent control equations can be calculated by differentiating (25) and setting them to zero:
To control the underactuated states of the hooks and DMPs through jib luffing movements, the sliding mode surface of coupled subsystems is defined as follows:
where and .
Based on equivalent control methods, the control input includes equivalent control inputs of each subsystem and switching control input, which are expressed as follows:
where is the switch control input.
To control the system state to converge to the desired states, the Lyapunov function is defined as follows:
Taking the derivative of (29) and substituting it into (28) yields
where , and . is the saturation function, which is defined as
, and .
In addition, the sliding surface of hoisting mechanisms is defined as follows:
where , and .
To control the hoisting mechanism to accurately track the desired rope length, deriving (33), introducing the switching control term in (31) in it, and meanwhile substituting (18) and the tracking errors of the hoisting mechanism in (23), the control law of hoisting mechanisms can be calculated as follows:
where .
In addition, the fast terminal sliding mode can converge to the equilibrium point in a finite time [28]. In detail, taking the sliding surface of hoisting mechanisms as an example, its convergence time is calculated as follows: when and assuming that the time required from the initial state to the sliding surface is , and , the time from to is
4. Simulation Results
In this section, to verify the effectiveness of the proposed method, multiple-group simulations are conducted based on MATLAB/Simulink R2024a environments.
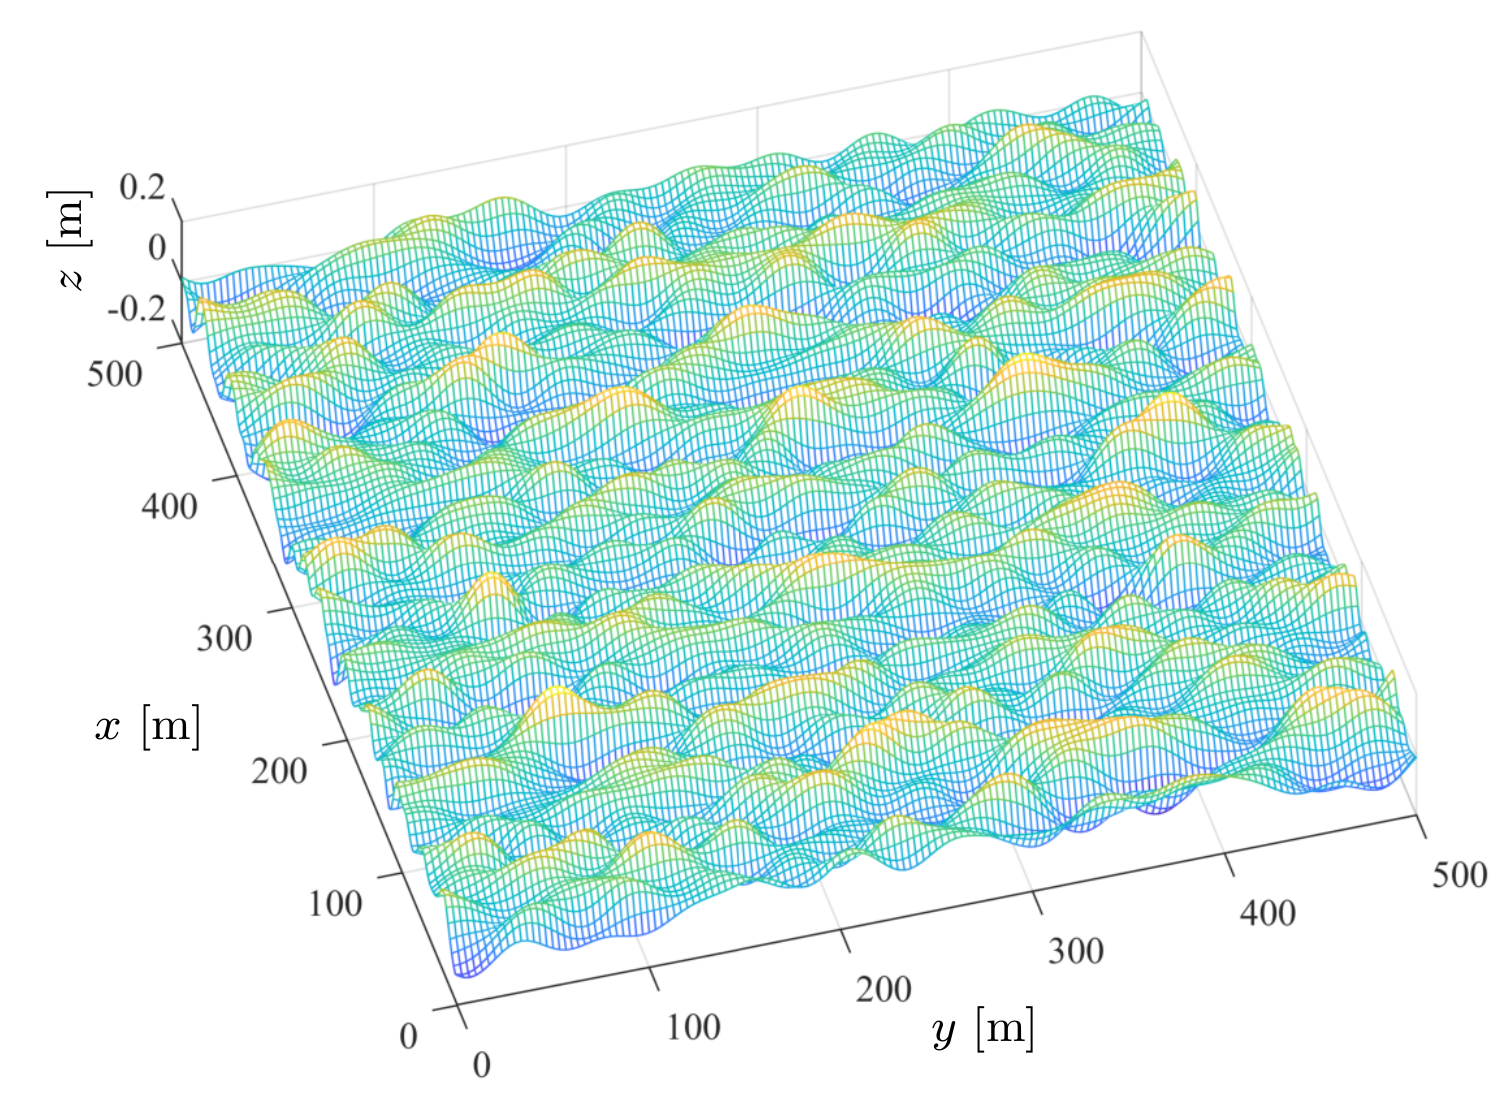
First, based on the offshore system simulator module, the wave simulation results can be obtained, as shown in Figure 2, where the significant wave height is set to 0.2 m, and more details are described in [29].
Figure 2.
Ocean wave simulation results.
Further, the control objective is set to . In simulation models, the parameters of a double-pendulum offshore crane with a DMP are set to = 0.1 m, = 0.2 m, = 0.16 m, = 0.5 kg, = 0.4 kg, = 0.3 kg, and g = 9.8 . In addition, the parameters of are set to Meanwhile, the parameters of are chosen as Additionally, it is worth pointing out that the controller parameters are optimized through a Simulink design optimization module.
4.1. Effectiveness Verification
This subsection will verify the effectiveness of the proposed method with a constant rope length and a variable rope length. The simulation conditions are set as follows:
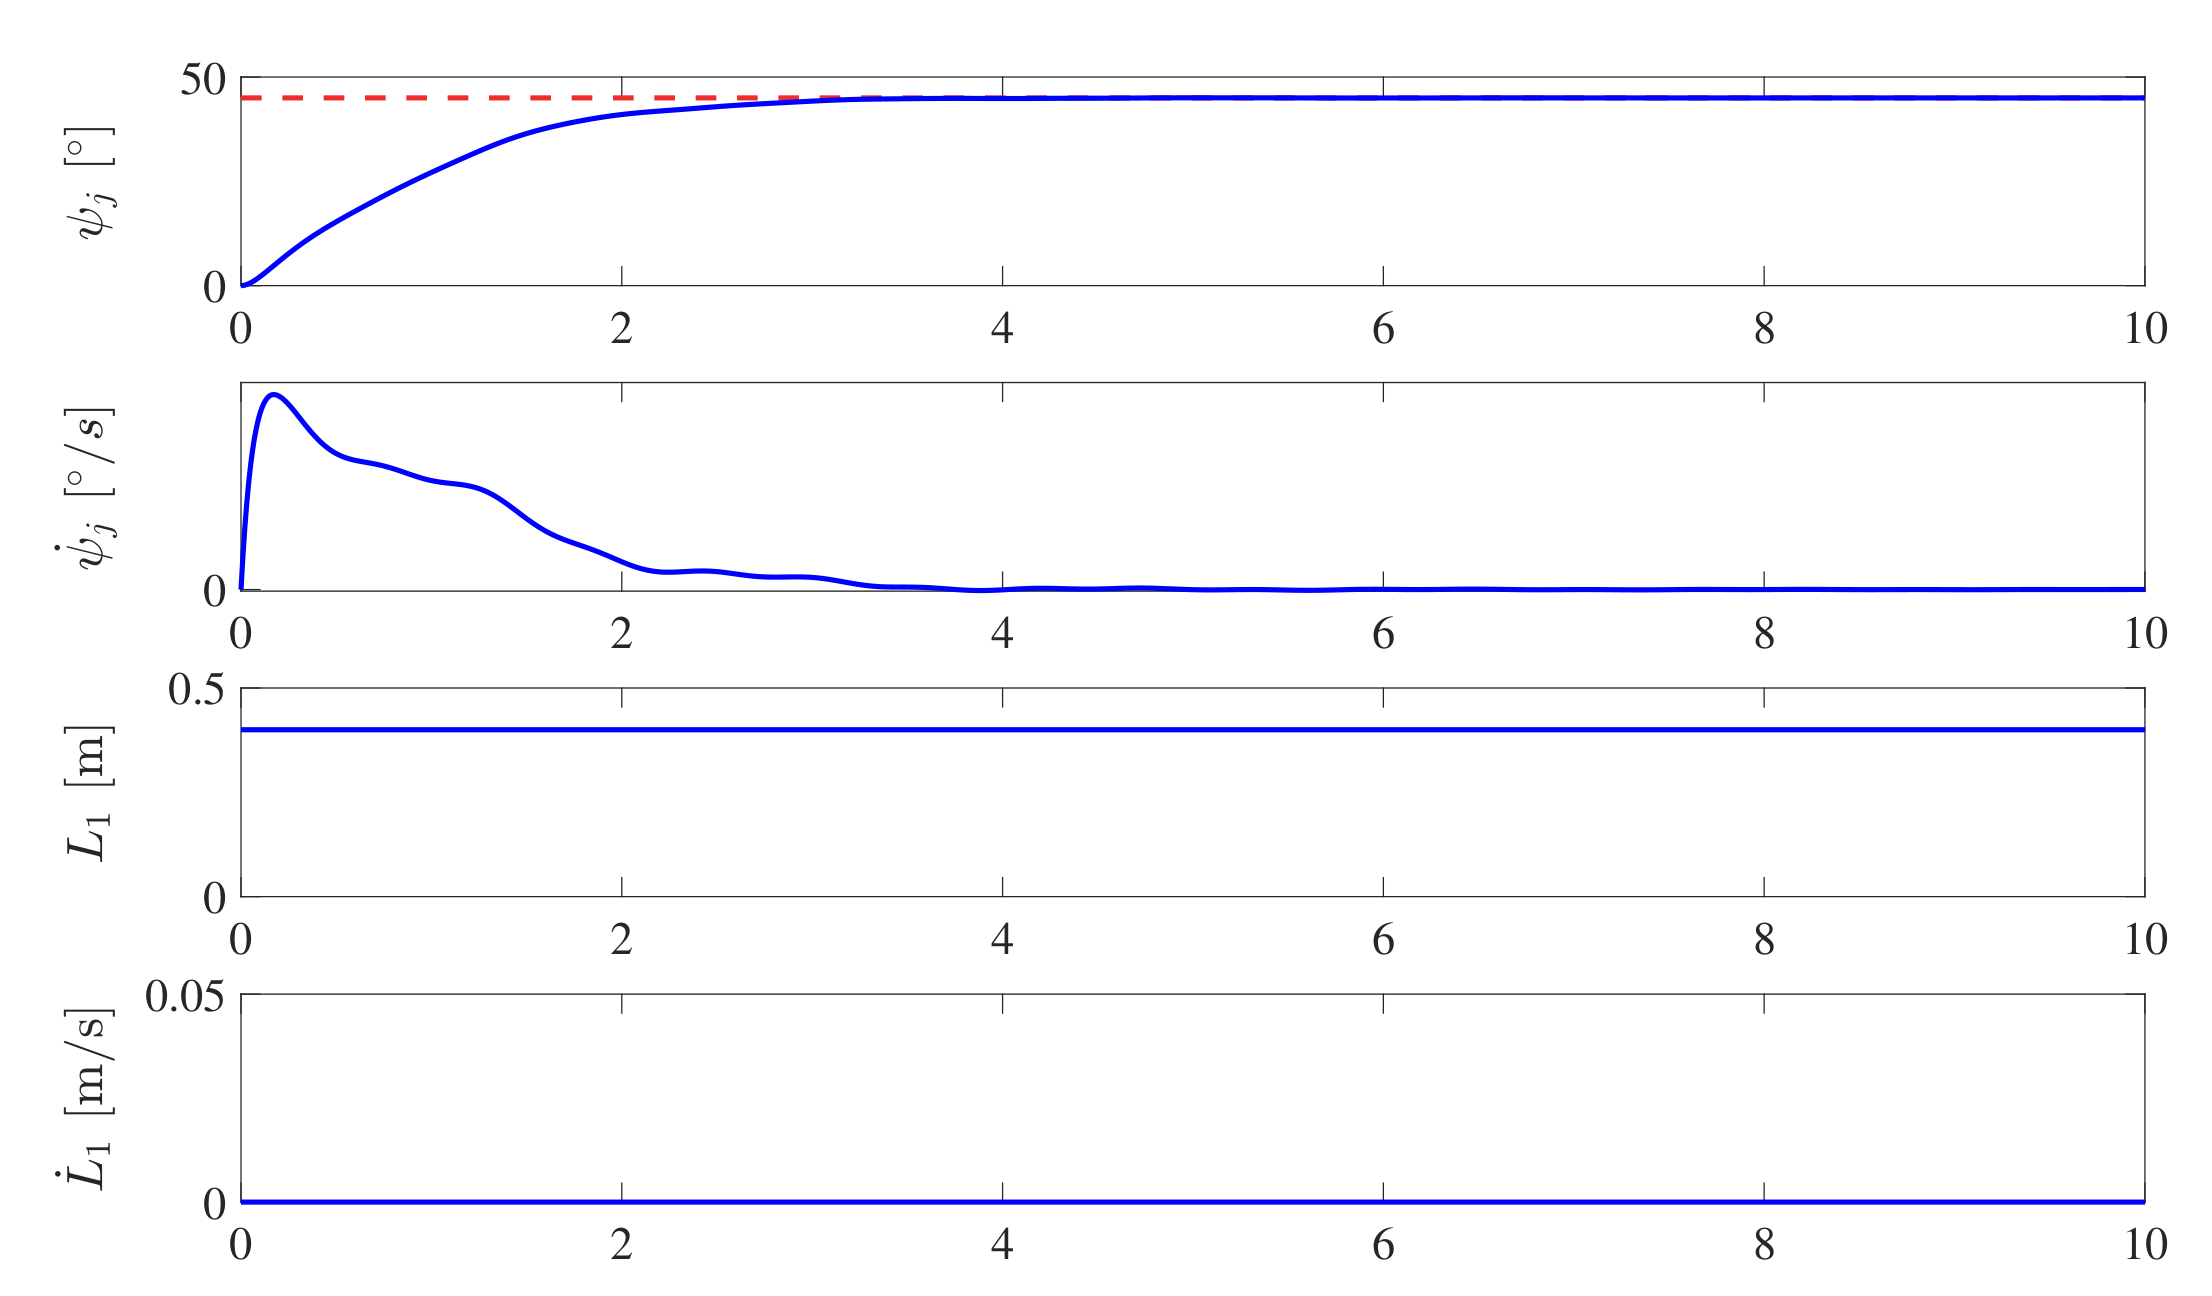
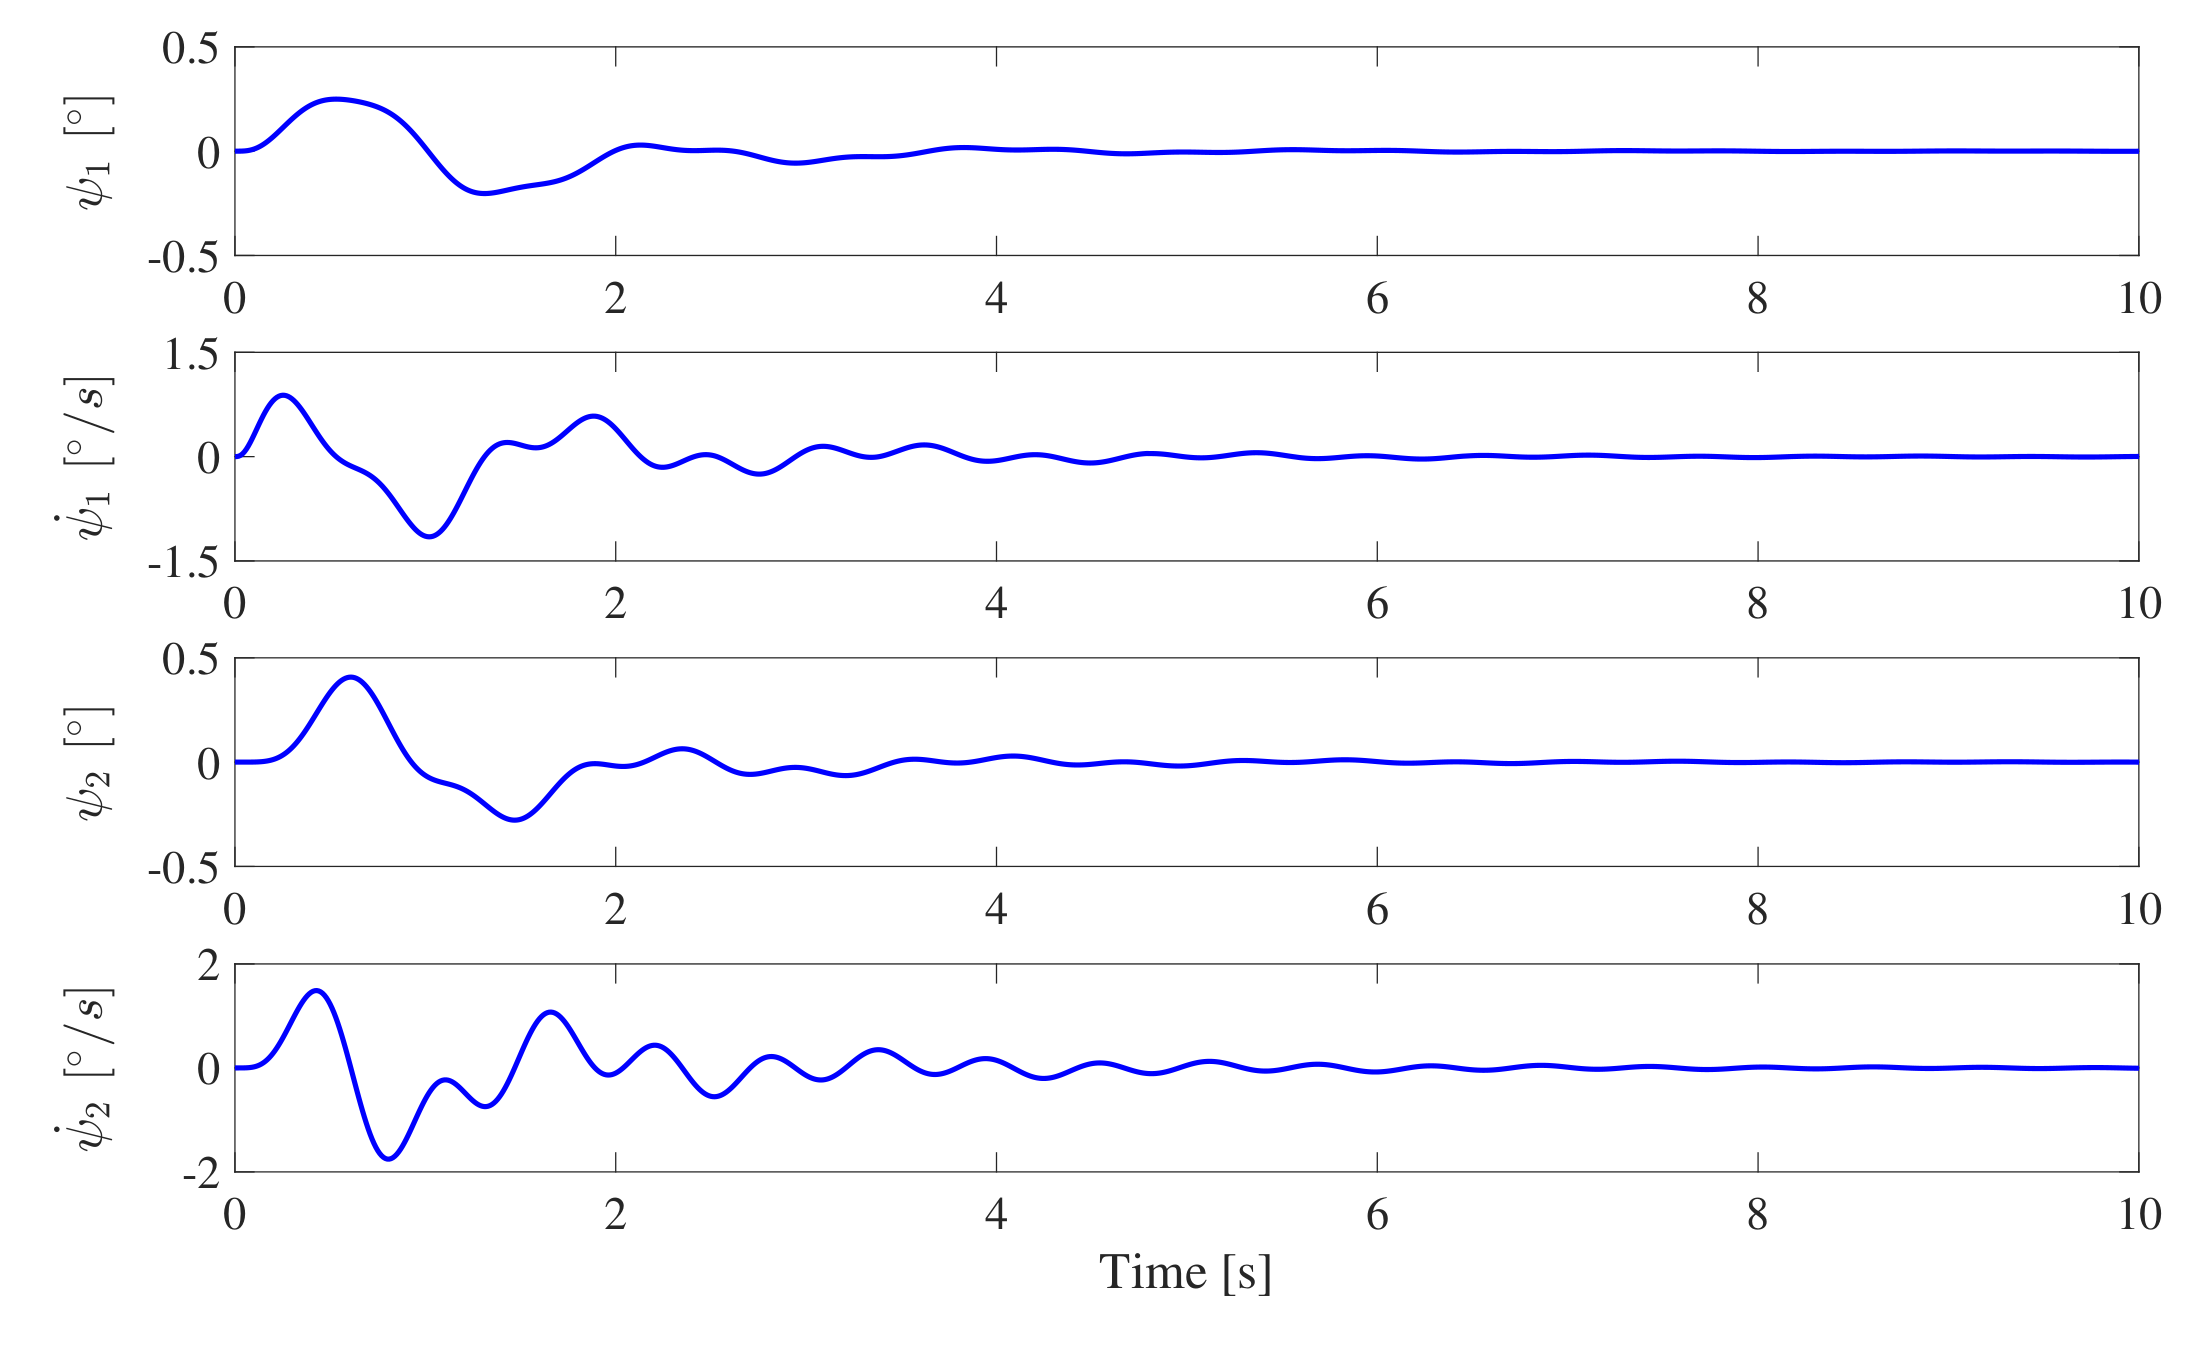
- Case 1. To simulate the DMP transportation process, the desired hoisting rope length is set to .
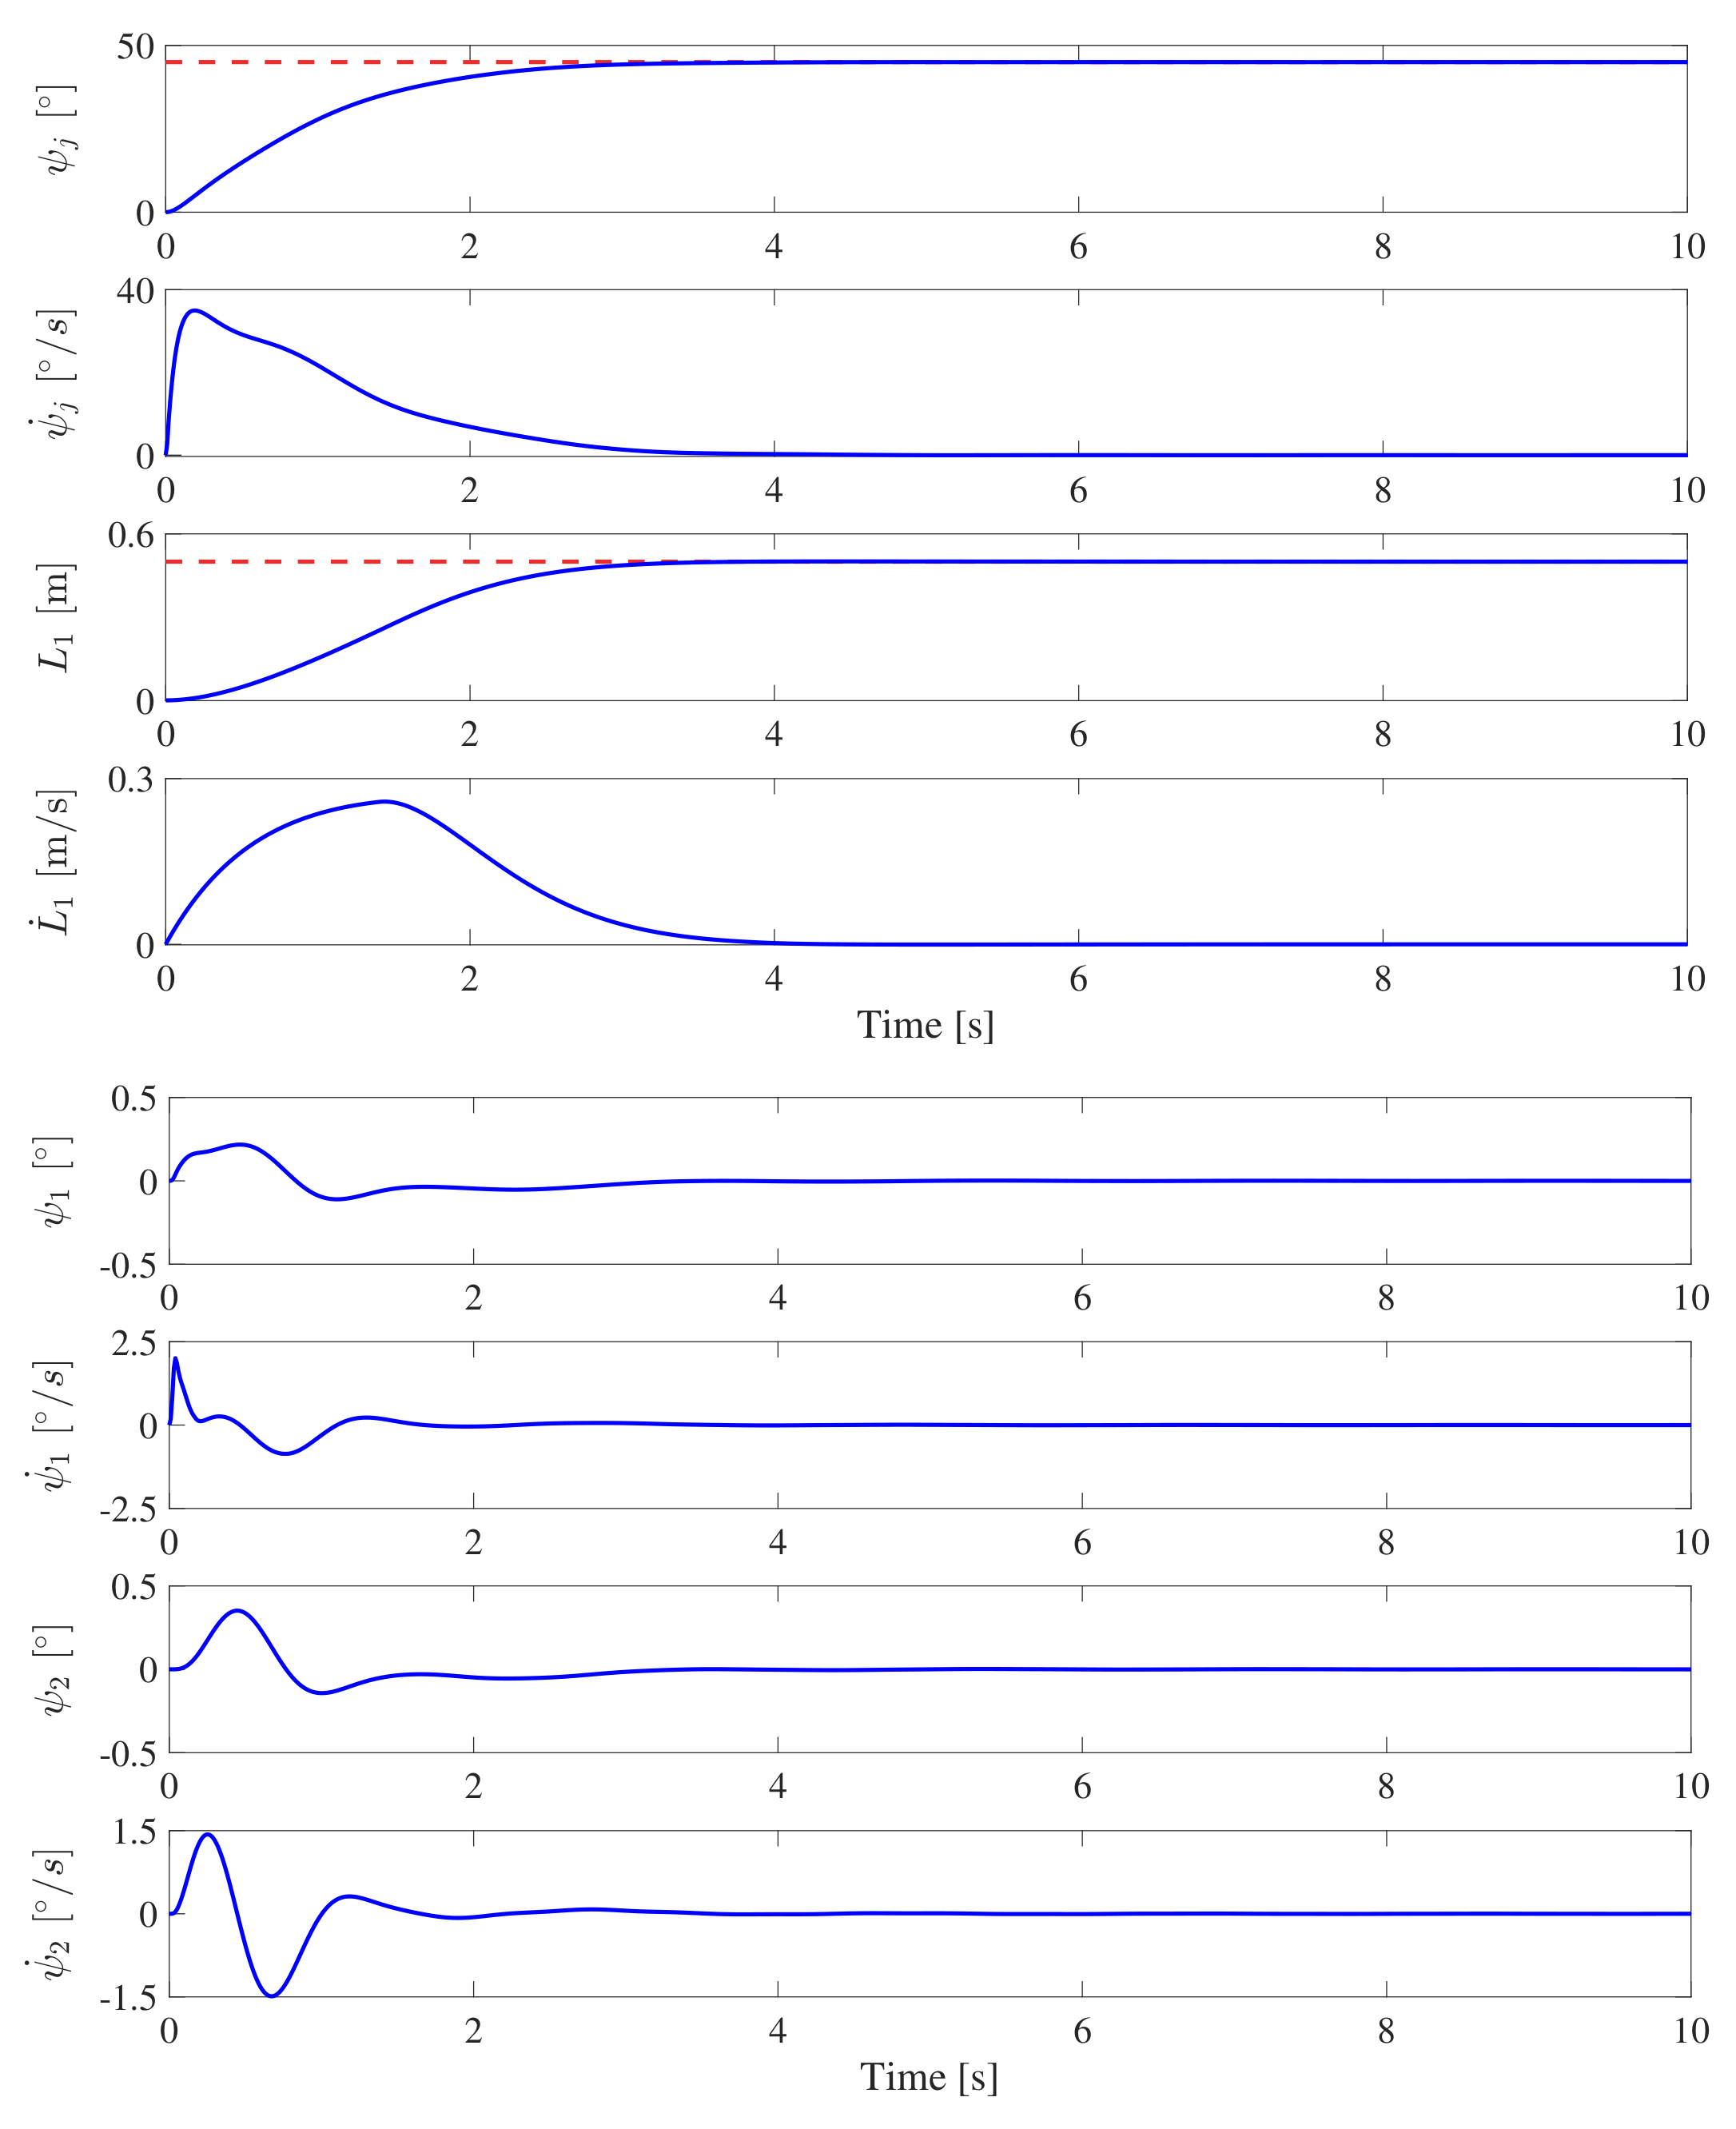
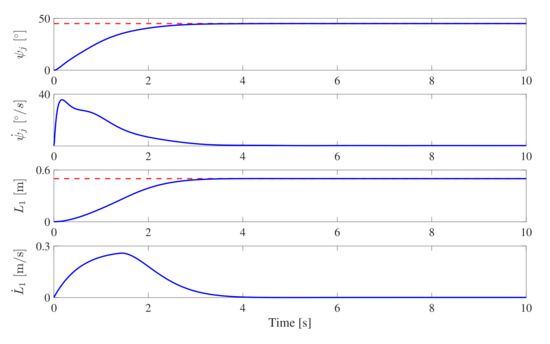
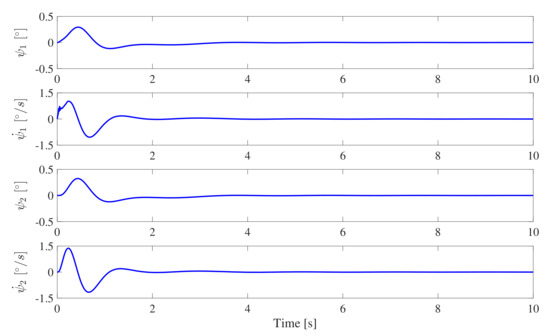
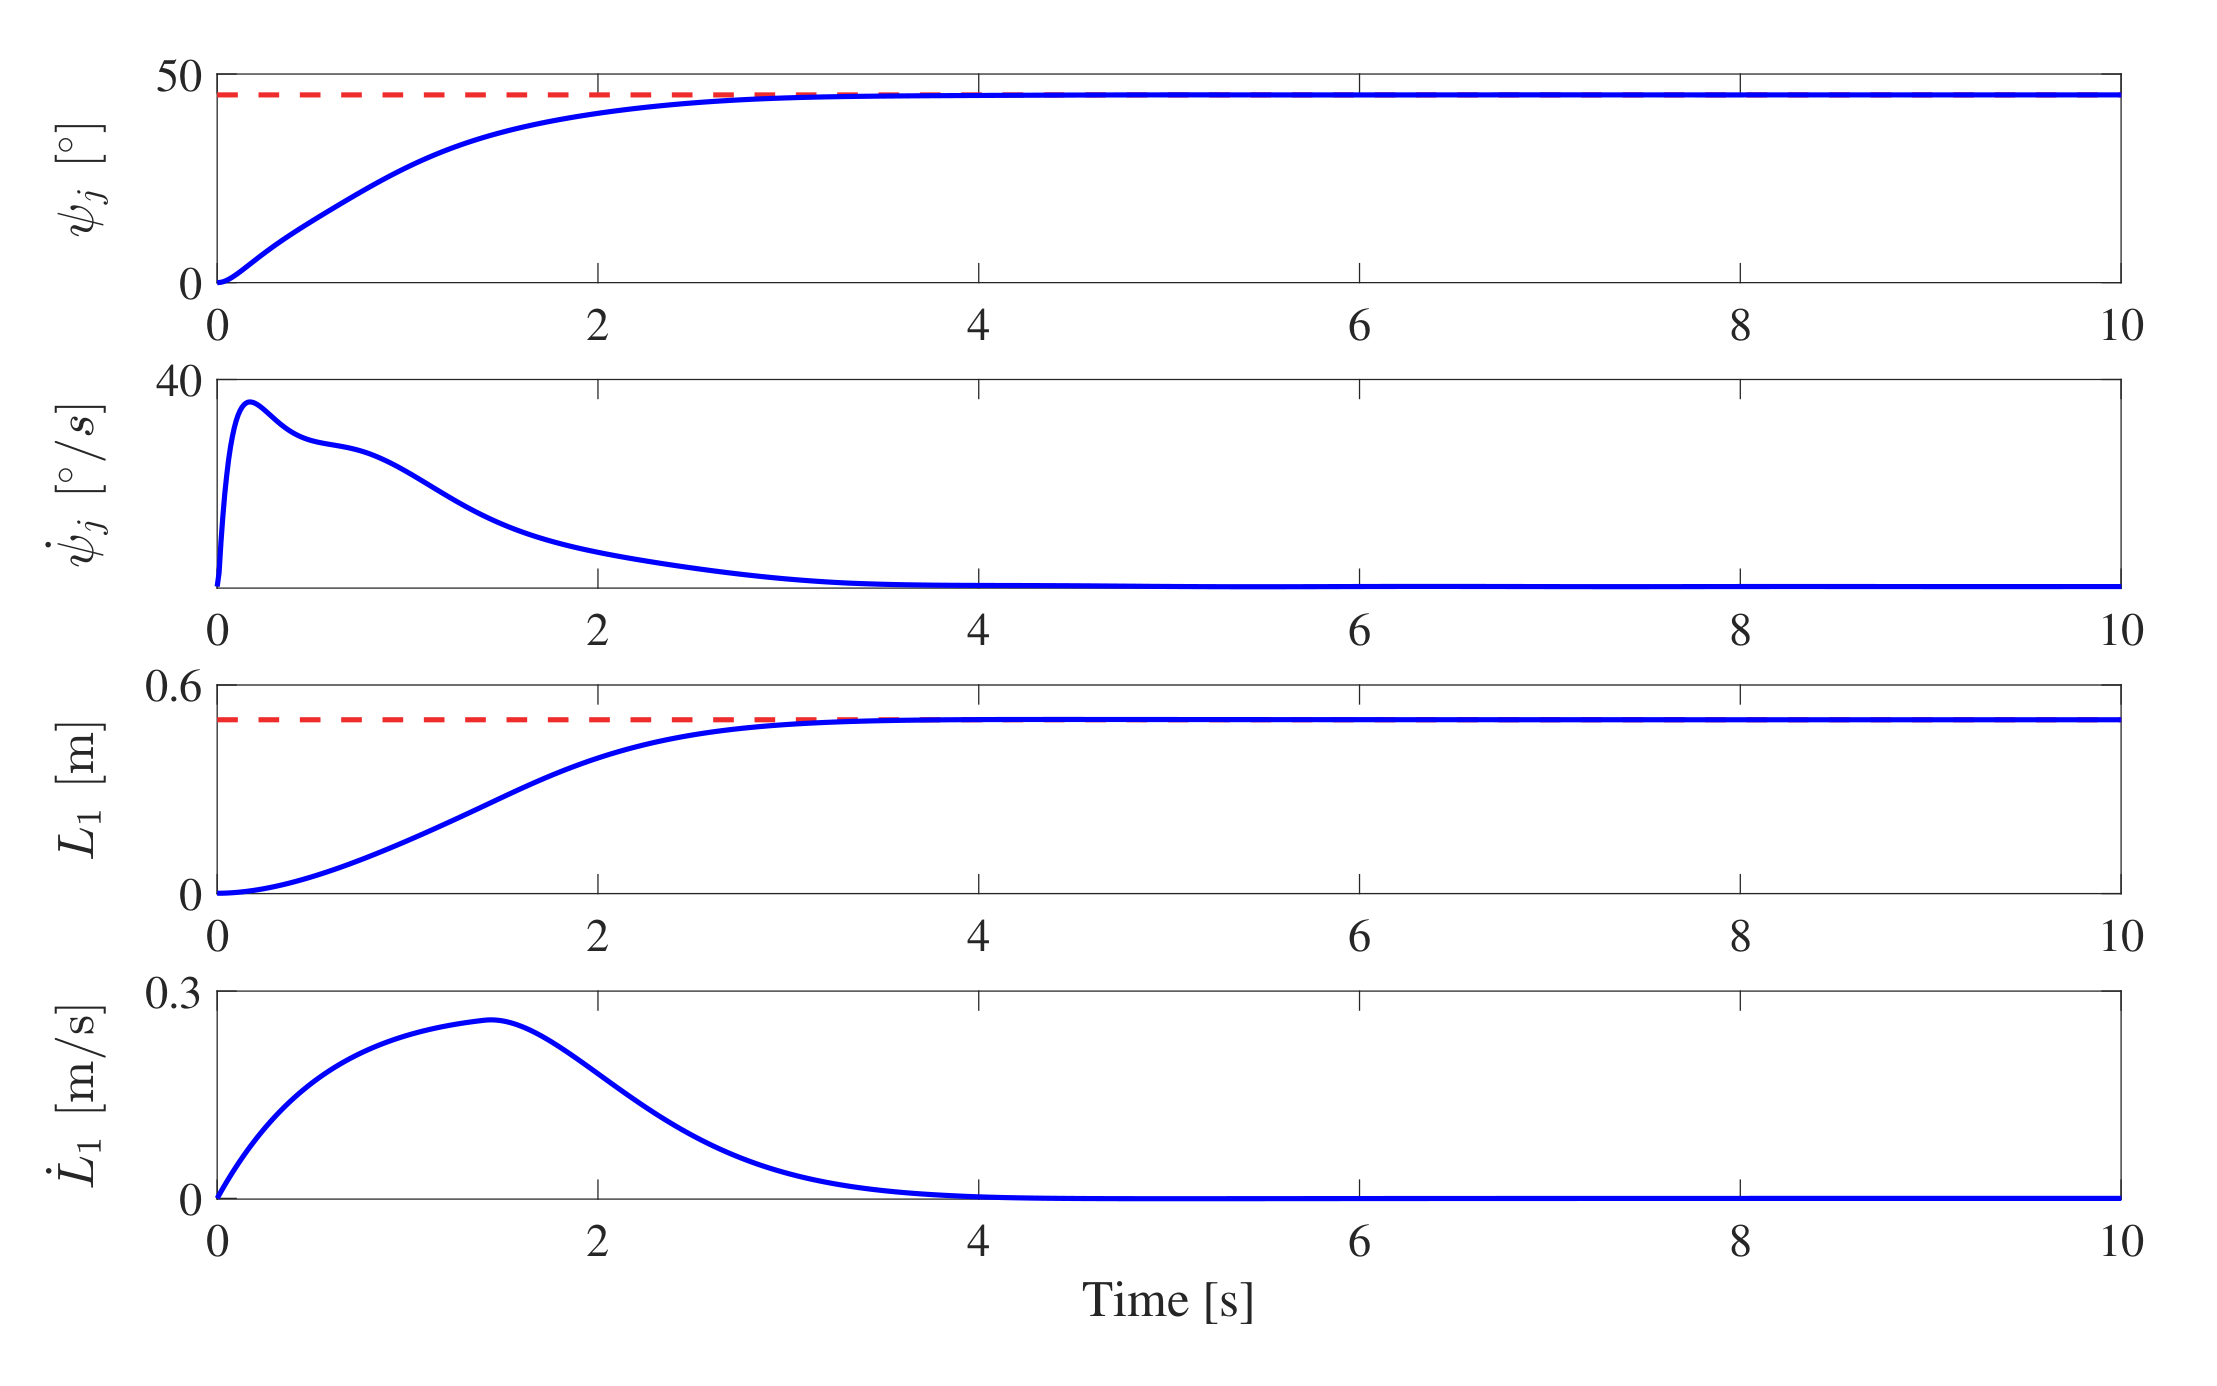
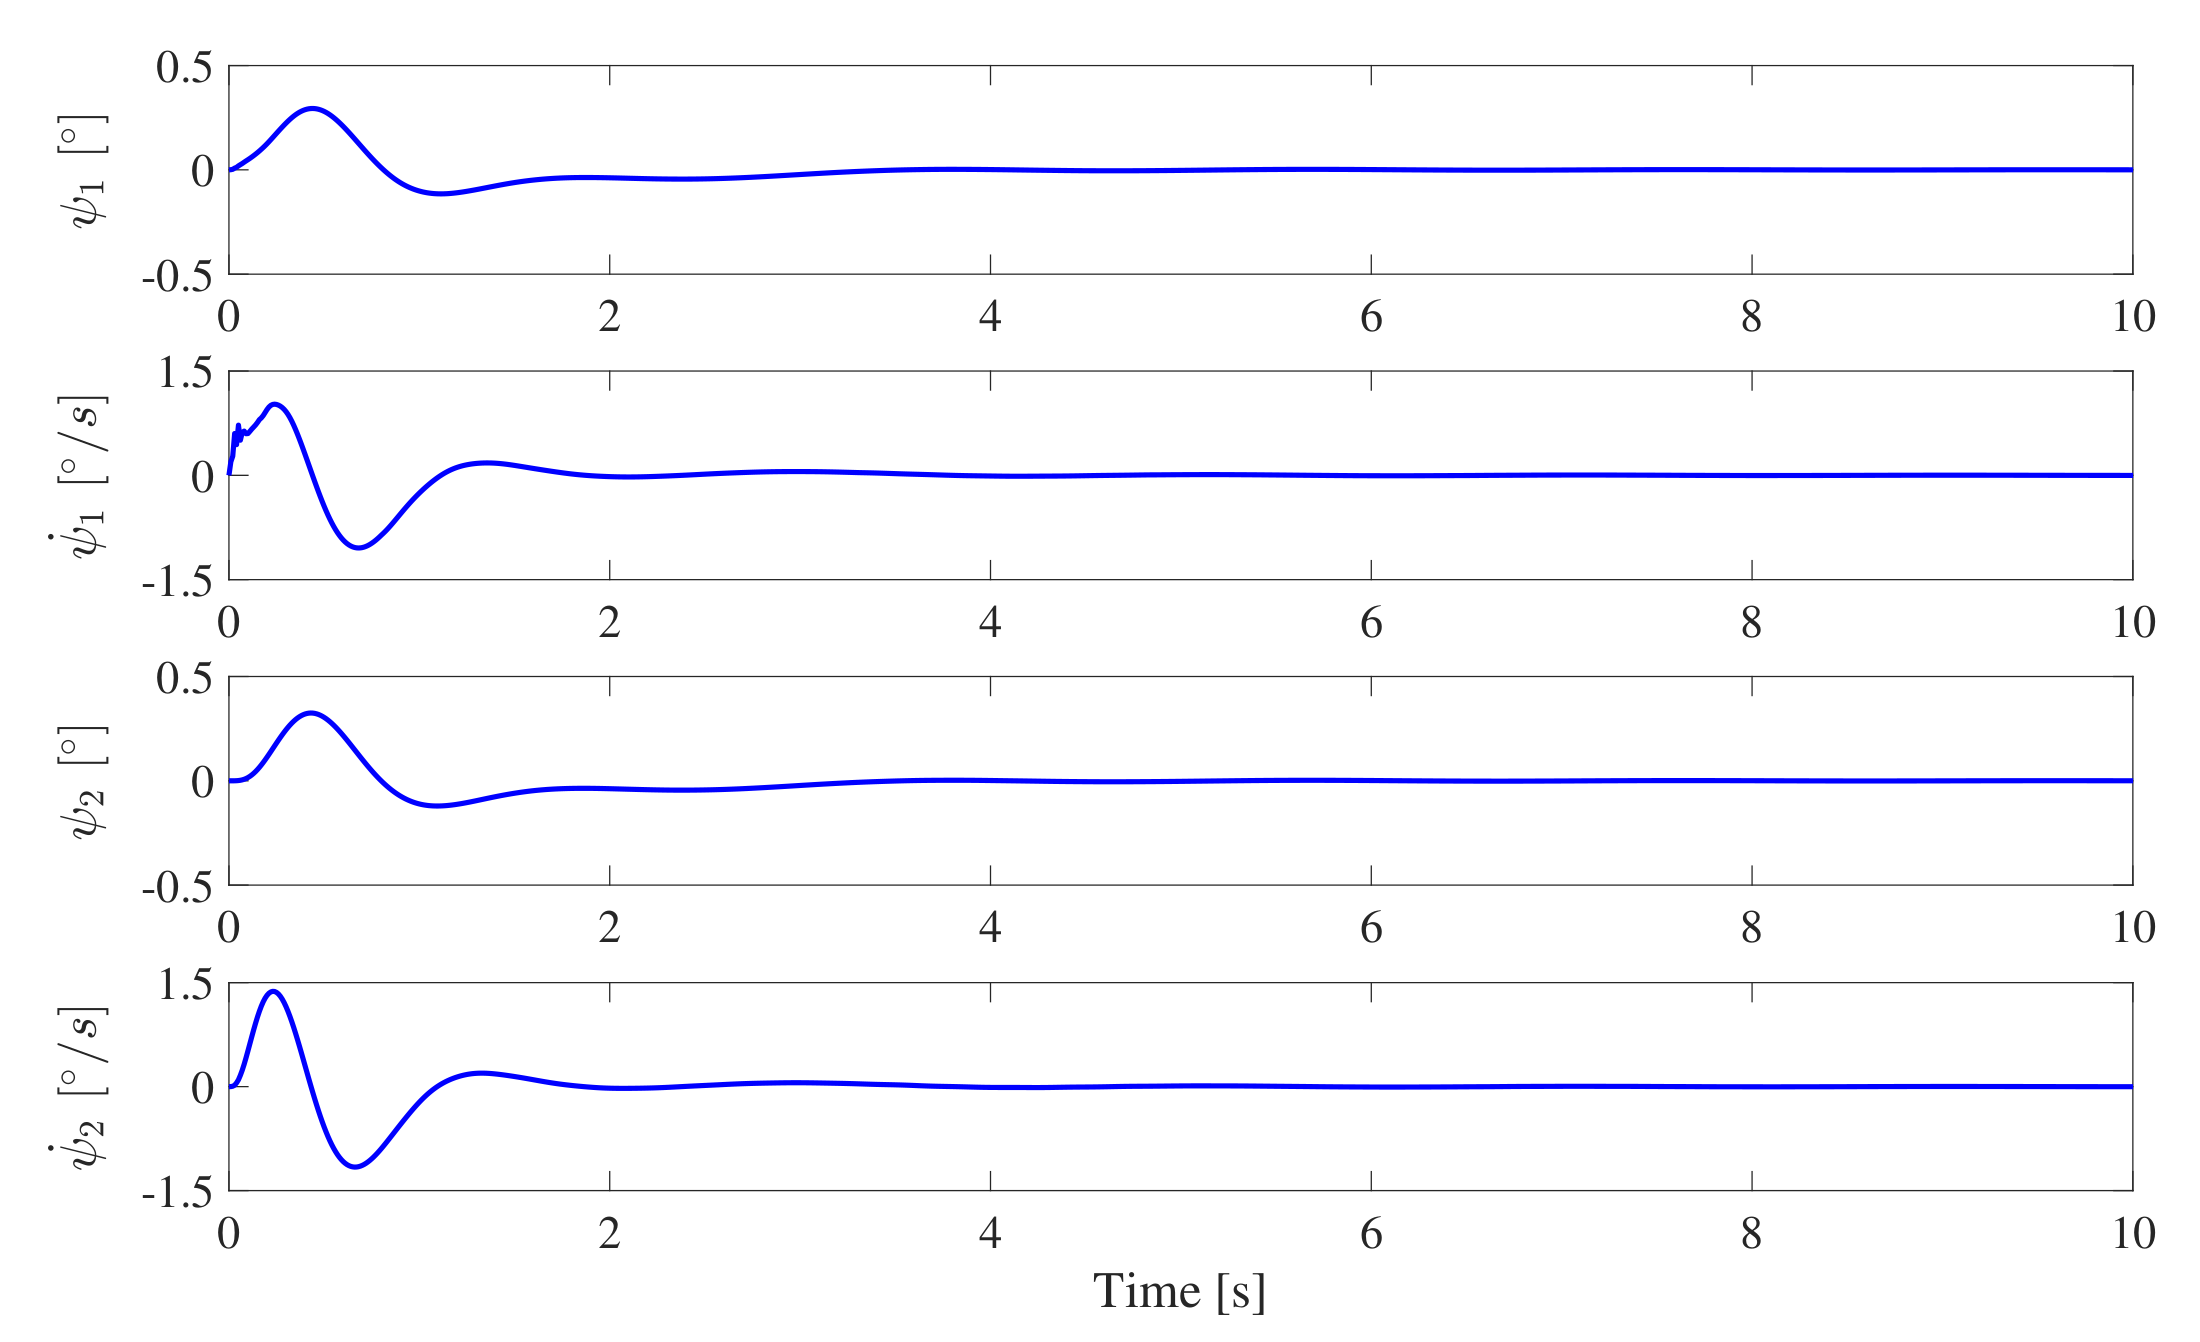
- Case 2. To improve the working efficiency of offshore cranes, marine cranes usually adopt the synchronous movement of pitching and hoisting. Therefore, to simulate this working condition, the initial hoisting rope length is set to 0 m, and the desired hoisting rope length is set to .
Figure 3 and Figure 4 describe the simulation results of the proposed method with constant rope lengths and variable rope lengths. Simulation results show that, under the same controller parameters, the proposed method can control the jib to run to the desired position without overshooting. At the same time, compared with the case where the rope length remains unchanged, the oscillations of the hook and DMP can also be effectively suppressed when the hoisting rope length changes, which demonstrates the effectiveness of the proposed method with variable hoisting rope lengths.
Figure 3.
Simulation results of Case 1 (red dashed lines denote the desired values).
Figure 4.
Simulation results of Case 2 (red dashed lines denote the desired values).
4.2. Robustness Verification
In practical applications, the DMP mass may be difficult to measure accurately in real time. In addition, the initial angle of the DMPs may not always be zero. Therefore, in this subsection, the robustness of the proposed method will be verified considering the DMP mass uncertainty and a non-zero initial angle. The rope length variation is the same as in Section 4.1, changing from 0 m to 0.5 m. The controller parameters also do not change. The following simulation conditions are set:
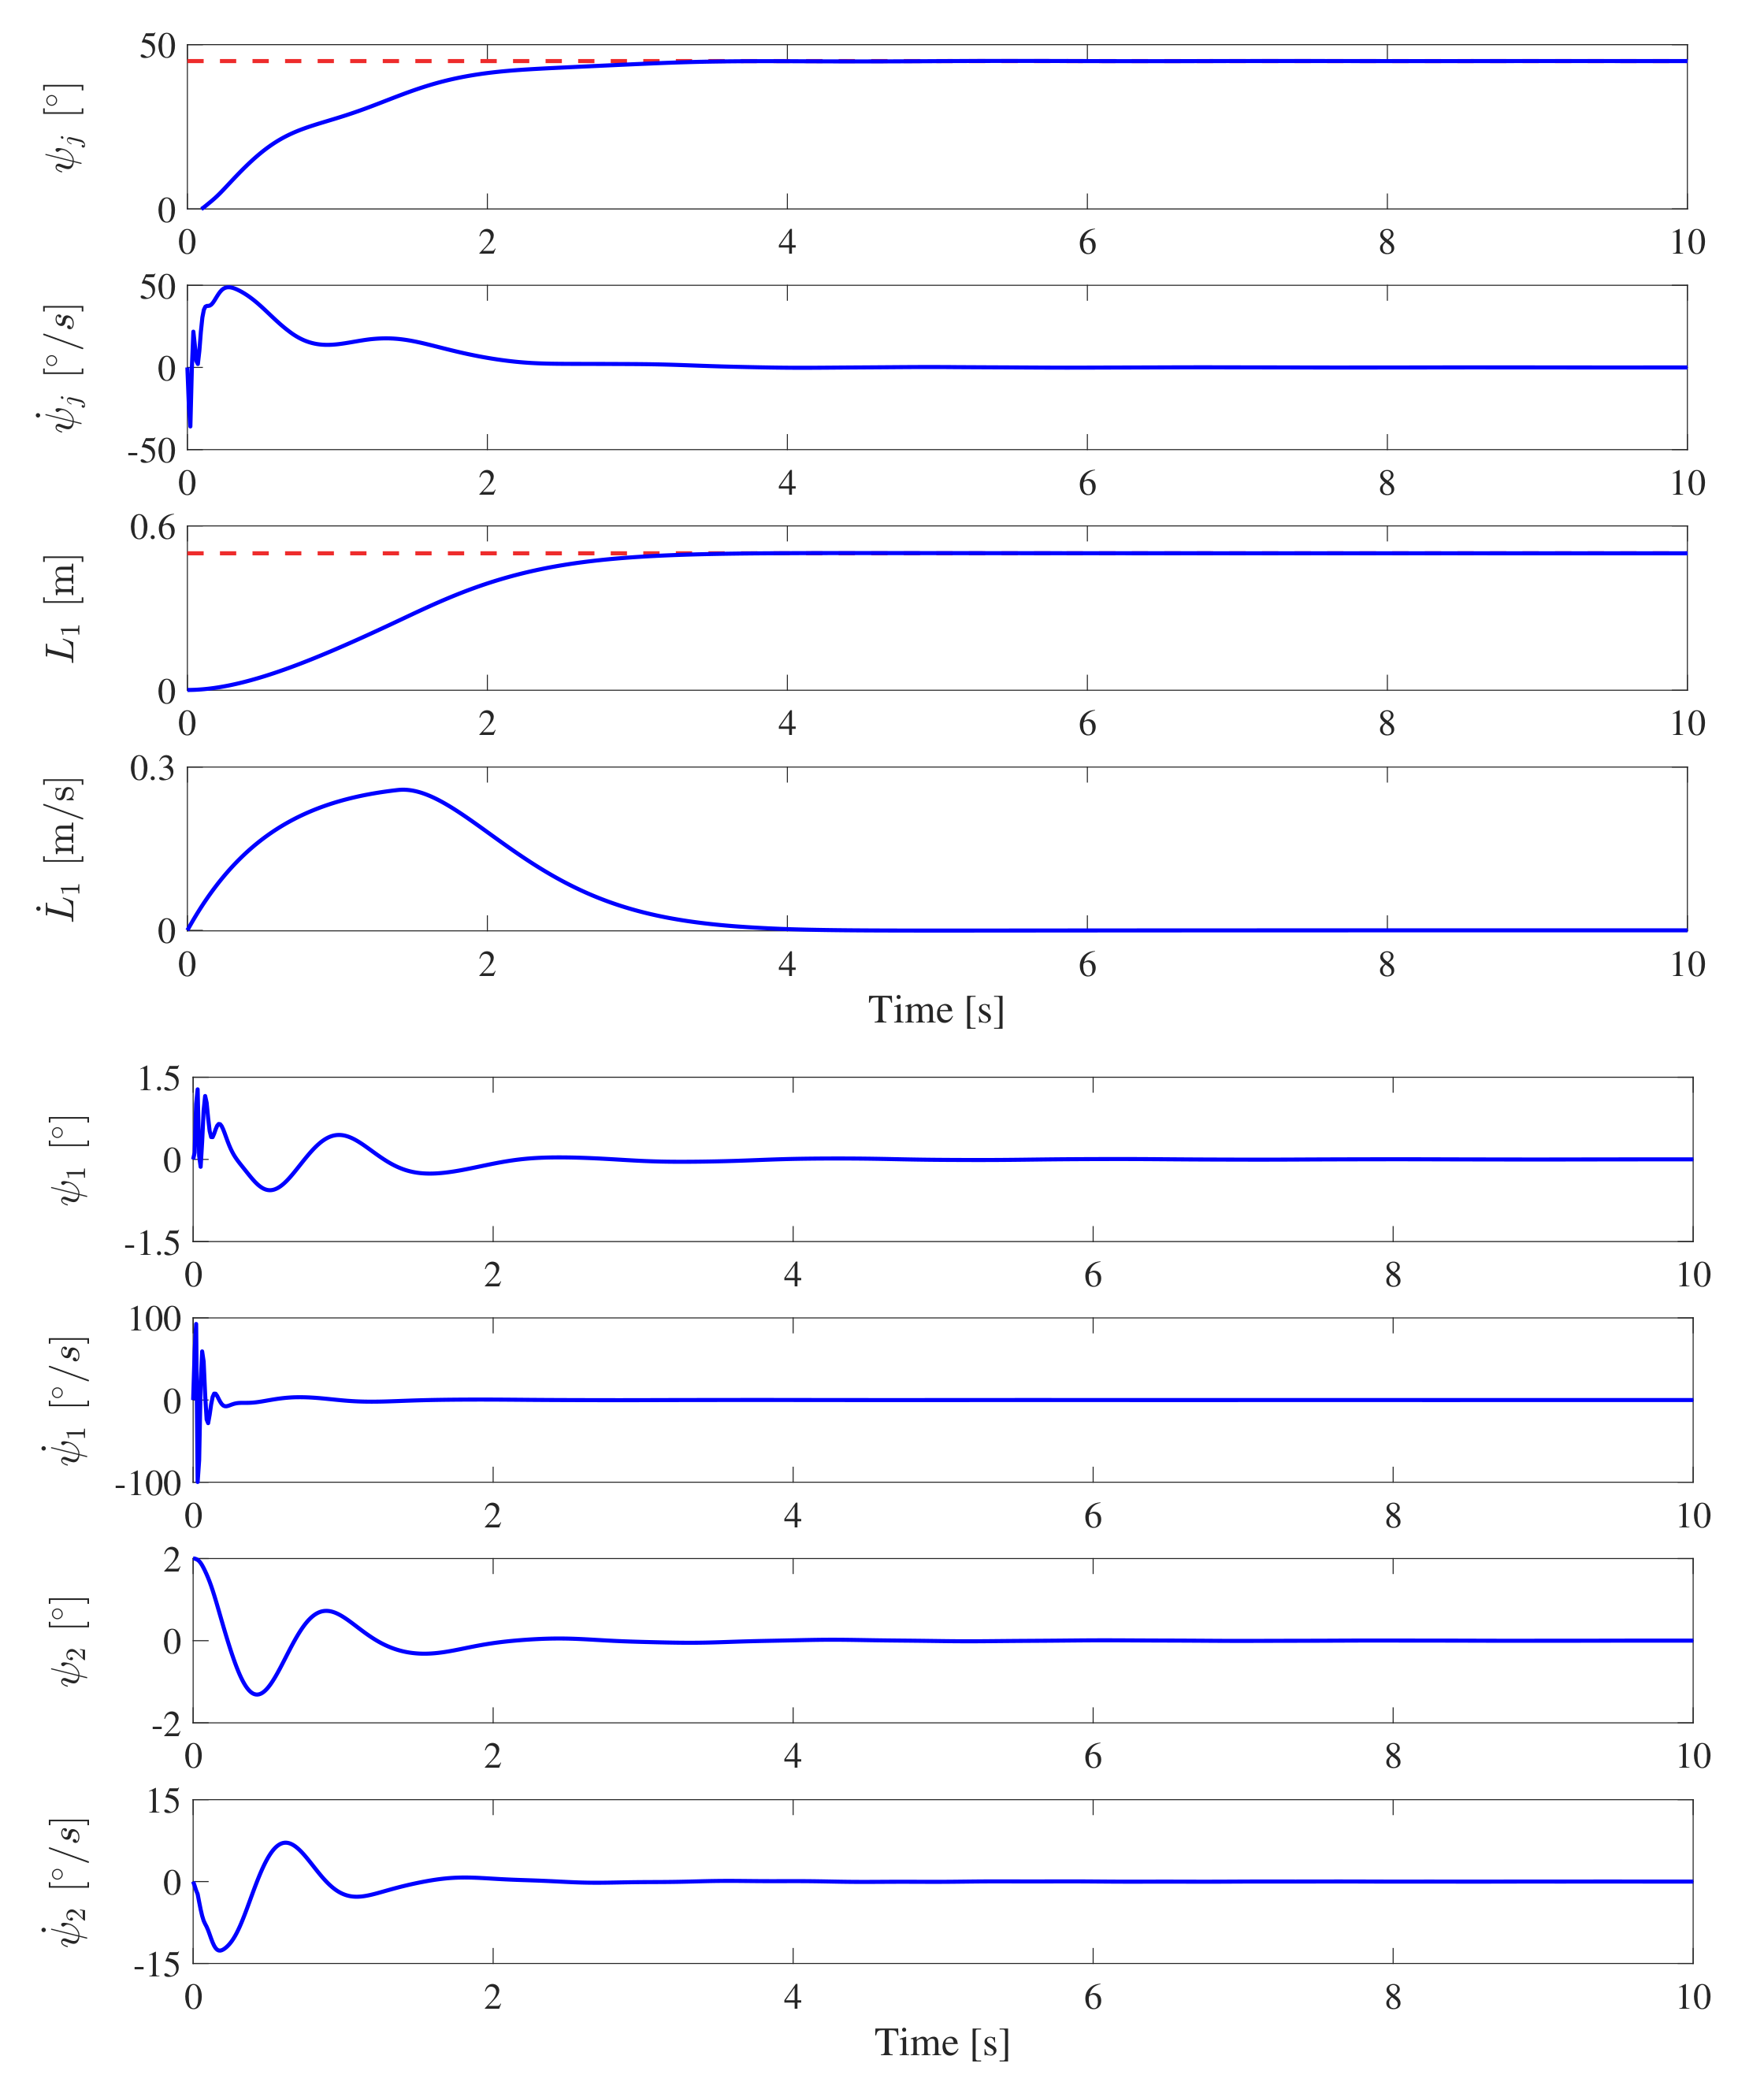
- Case 3.Assume that the DMP has an initial angle, whose value is set to .
- Case 4. In actual applications, the DMP mass may not be measured accurately. Therefore, the DMP mass in the offshore cranes and proposed controllers is set to 3.5 kg and 0.5 kg, respectively.
Figure 5 and describe the simulation results of the proposed method with a non-zero initiate angle and variable DMP mass. As shown in Figure 5, when a DMP has a non-zero initial angle and the offshore crane starts to operate, the DMP will swing under gravity, which will affect the operation of the hook and cause it to oscillate violently. However, under the action of the proposed control method, the offshore crane will quickly stabilize, including the jib reaching the desired angle, the rope length reaching the desired length, and the angles of the hook and DMP converging to zero. In addition, as shown in Figure 6, in the initial stage, the uncertain DMP mass will affect the dynamic characteristics of the hook, causing it to oscillate slightly. Subsequently, offshore cranes will tend to stabilize and converge to desired values, demonstrating the robustness of the proposed method to the DMP mass uncertainty. To sum up, the proposed method is robust to non-zero initial angles and DMP mass uncertainties.
Figure 5.
Simulation results of Case 3 (red dashed lines denote the desired values).
Figure 6.
Simulation results of Case 4 (red dashed lines denote the desired values).
4.3. Comparative Simulation Considering Disturbances
To verify the good control performance of the proposed method, a set of comparative simulations is carried out. The rope length variation is the same as in Case 2 in Section 4.1. The controller parameters are also the same as in Section 4.1. As the most widely used controller in the industry, the PID controller is selected as a comparative method, which is expressed as follows:
where denote the parameters of the PID controller, which are set as .
In addition, actual offshore cranes are inevitably affected by external wind, so the following wind disturbance simulation signals are designed:
- Case 5. At 10 s, an impulsive disturbance with an amplitude of is added, which is adopted to simulate the impact of disturbance on DMPs.
- Case 6. Between 20 s and 21 s, sine wave disturbances with an amplitude of and a period of are added, which are utilized to simulate periodic sea breeze disturbances.
- Case 7. To simulate random sea breeze disturbances, between 30 s and 31 s, random disturbances with max and min amplitudes of and , respectively, are applied on DMPs. In addition, the sample time is 0.1 s.
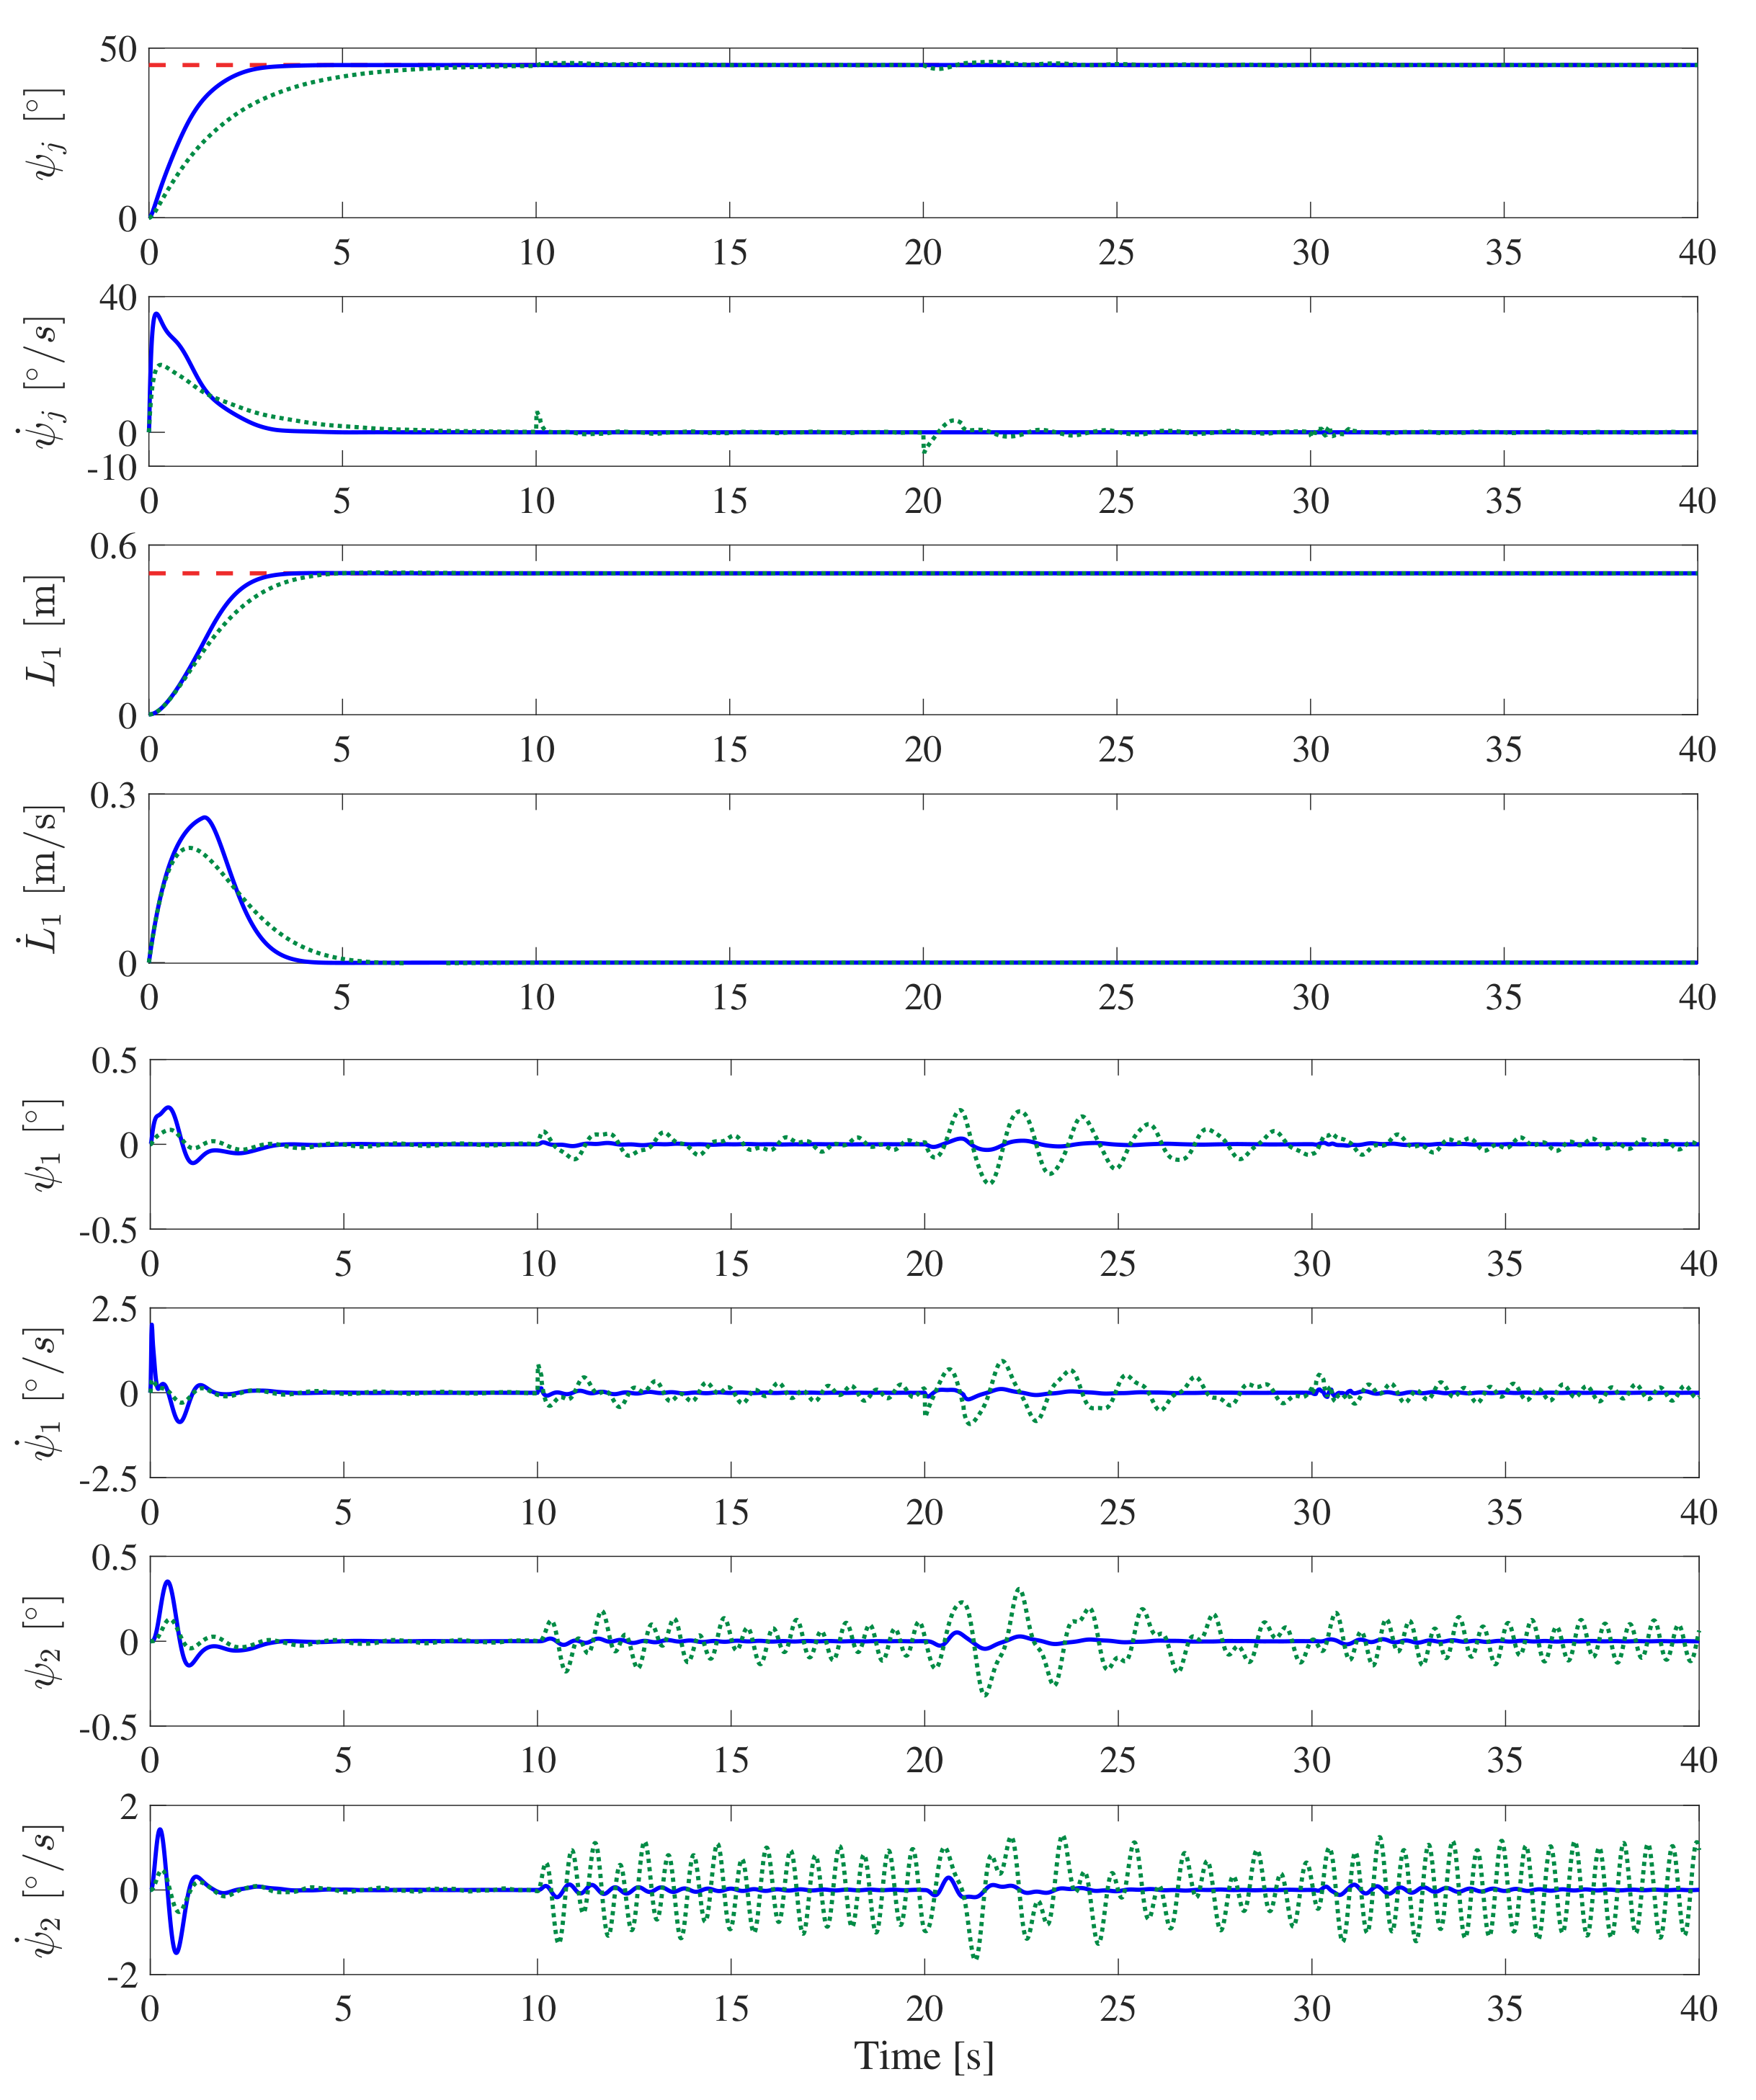
Figure 7 depicts the comparative simulation results of the proposed method with different disturbances. As shown in Figure 7, when there are no external disturbances, both the proposed controller and the PID controller can suppress the oscillations of the hook and DMP. However, the proposed controller converges faster than the PID controller, which will be beneficial to improve the working efficiency of offshore cranes. In addition, when subjected to external disturbances, the proposed controller can effectively suppress the oscillations of the hook and DMP, but the performance of the PID controller decreases significantly and even regionally diverges, which is dangerous for offshore crane operation and may even cause safety accidents. Quantitative data show that in the disturbance suppression stage, the maximum hook and load swing angles of the proposed method are and , respectively, which are much smaller than the and of the PID method.
Figure 7.
Comparative simulation results. The proposed method with blue solid lines; The PID method with green dashed lines (red dashed lines denote the desired values).
5. Conclusions
In this paper, a novel adaptive control method has been proposed for double-pendulum offshore cranes hoisting DMPs. First, a nonlinear dynamic model has been established based on Lagrange’s methods. Then, based on acceleration input control patterns, a fast terminal sliding mode control method has been proposed to suppress oscillations and achieve accurate position under the condition of hoisting rope length variation. Simulation results have demonstrated the effectiveness of the proposed method. The robustness of the proposed method to the mass parameter uncertainty of DMPs and external disturbances has been verified by multiple groups of simulations. In the future, the effectiveness of the proposed method will be verified based on a self-built experimental platform. The center of gravity of the ship and the rotation axis of the offshore crane will be considered in the dynamic model. At the same time, appropriate methods will be designed to deal with nonlinear factors such as hysteresis in hydraulic systems to further improve the system control performance.
Author Contributions
Conceptualization, Q.W.; methodology, Q.W.; software, Y.J.; validation, N.L., S.G. and Q.W.; formal analysis, N.L.; investigation, S.G.; resources, W.H. and Y.L.; data curation, S.G.; writing—original draft preparation, N.L. and S.G.; writing—review and editing, Q.W.; visualization, Y.W. and Y.J.; supervision, Q.W., T.Y. and N.S.; project administration, Q.W.; funding acquisition, Q.W. All authors have read and agreed to the published version of the manuscript.
Funding
This research was supported by the State Key Laboratory of Robotics and Systems (HIT) under grant SKLRS-2023-KF-13, the National Natural Science Foundation of China under grant 52205019, and the Guangdong Basic and Applied Basic Research Foundation under grant 2023A1515012669. Shudong Guo and Nan Li contributed equally to this work.
Data Availability Statement
Data are contained within the article.
Conflicts of Interest
The authors declare no conflicts of interest.
Abbreviations
The following abbreviations are used in this manuscript:
| DMP | distributed-mass payload |
| PD | proportional derivative |
References
- Li, Z.; Chen, H.; Che, L. Antiswing control of offshore cranes under ship rolling disturbances: An active disturbance rejection control based approach. Nonlinear Dyn. 2024, 112, 21097–21116. [Google Scholar] [CrossRef] [Scilit]
- Ren, Z.; Verma, A.S.; Ataei, B.; Halse, K.H.; Hildre, H.P. Model-free anti-swing control of complex-shaped payload with offshore floating cranes and a large number of lift wires. Ocean. Eng. 2021, 228, 108868. [Google Scholar] [CrossRef] [Scilit]
- Yang, T.; Sun, N.; Chen, H.; Fang, Y. Adaptive optimal motion control of uncertain underactuated mechatronic systems with actuator constraints. IEEE/ASME Trans. Mechatronics 2022, 28, 210–222. [Google Scholar] [CrossRef] [Scilit]
- Ismail, R.R.; That, N.D.; Ha, Q.P. Modelling and robust trajectory following for offshore container crane systems. Autom. Constr. 2015, 59, 179–187. [Google Scholar] [CrossRef] [Scilit]
- Sun, M.; Zhao, T.; Wang, S.; Han, G.; Jin, G.; Chen, H.; Sun, Y. Dynamic analysis and experimental research on slender-beam payload swing suppression for marine crane retrofitted a multi-tagline parallel anti-swing system. Ocean. Eng. 2024, 296, 116922. [Google Scholar] [CrossRef] [Scilit]
- Ye, J.; Roy, S.; Godjevac, M.; Baldi, S. A switching control perspective on the offshore construction scenario of heavy-lift vessels. IEEE Trans. Control Syst. Technol. 2020, 29, 470–477. [Google Scholar] [CrossRef] [Scilit]
- Kim, G.H.; Pham, P.T.; Ngo, Q.H.; Nguyen, Q.C. Neural network-based robust anti-sway control of an industrial crane subjected to hoisting dynamics and uncertain hydrodynamic forces. Int. J. Control Autom. Syst. 2021, 19, 1953–1961. [Google Scholar] [CrossRef] [Scilit]
- Kim, G.H.; Hong, K.S. Adaptive sliding-mode control of an offshore container crane with unknown disturbances. IEEE/ASME Trans. Mechatronics 2019, 24, 2850–2861. [Google Scholar] [CrossRef] [Scilit]
- Yang, T.; Chen, H.; Sun, N.; Fang, Y. Adaptive neural network output feedback control of uncertain underactuated systems with actuated and unactuated state constraints. IEEE Trans. Syst. Man Cybern. Syst. 2021, 52, 7027–7043. [Google Scholar] [CrossRef] [Scilit]
- Cao, Y.; Li, T. Review of antiswing control of shipboard cranes. IEEE/CAA J. Autom. Sin. 2020, 7, 346–354. [Google Scholar] [CrossRef] [Scilit]
- Sun, N.; Fang, Y.; Chen, H.; Fu, Y.; Lu, B. Nonlinear stabilizing control for ship-mounted cranes with ship roll and heave movements: Design, analysis, and experiments. IEEE Trans. Syst. Man Cybern. Syst. 2017, 48, 1781–1793. [Google Scholar] [CrossRef] [Scilit]
- McKenzie, R.A.; Irani, R.A. Motion compensation for maritime cranes during time-varying operations at the pendulum’s natural frequency. Mech. Mach. Theory 2022, 168, 104573. [Google Scholar] [CrossRef] [Scilit]
- Qian, Y.; Hu, D.; Chen, Y.; Fang, Y. Programming-based optimal learning sliding mode control for cooperative dual ship-mounted cranes against unmatched external disturbances. IEEE Trans. Autom. Sci. Eng. 2022, 20, 969–980. [Google Scholar] [CrossRef] [Scilit]
- Sun, M.; Wang, S.; Han, G.; Jin, G.; Li, J.; Chen, H.; Sun, Y. Multi-cable anti-swing system for cranes subject to ship excitation and wind disturbance: Dynamic analysis and application in engineering. Ocean. Eng. 2023, 281, 114518. [Google Scholar] [CrossRef]
- Martin, I.A.; Irani, R.A. A generalized approach to anti-sway control for shipboard cranes. Mech. Syst. Signal Process. 2021, 148, 107168. [Google Scholar] [CrossRef] [Scilit]
- Qian, Y.; Zhang, H.; Hu, D. Finite-time neural network-based hierarchical sliding mode antiswing control for underactuated dual ship-mounted cranes with unmatched sea wave disturbances suppression. IEEE Trans. Neural Netw. Learn. Syst. 2023, 35, 12396–12408. [Google Scholar] [CrossRef] [Scilit]
- Zhai, M.; Yang, T.; Sun, N.; Fang, Y. Observer-based adaptive fuzzy control of underactuated offshore cranes for cargo stabilization with respect to ship decks. Mech. Mach. Theory 2022, 175, 104927. [Google Scholar] [CrossRef] [Scilit]
- Guo, B.; Chen, Y. Fuzzy robust fault-tolerant control for offshore ship-mounted crane system. Inf. Sci. 2020, 526, 119–132. [Google Scholar] [CrossRef] [Scilit]
- Li, Z.; Ma, X.; Li, Y. Nonlinear partially saturated control of a double pendulum offshore crane based on fractional-order disturbance observer. Autom. Constr. 2022, 137, 104212. [Google Scholar] [CrossRef] [Scilit]
- Wang, Y.; Yang, T.; Zhai, M.; Fang, Y.; Sun, N. Ship-mounted cranes hoisting underwater payloads: Transportation control with guaranteed constraints on overshoots and swing. IEEE Trans. Ind. Inform. 2023, 19, 9968–9978. [Google Scholar] [CrossRef] [Scilit]
- Sun, M.; Luan, T.; Tan, Z.; Wang, W. Swing reduction control of ship crane based on rope length change. Arab. J. Sci. Eng. 2023, 48, 15597–15608. [Google Scholar] [CrossRef] [Scilit]
- Tang, R.; Huang, J. Control of bridge cranes with distributed-mass payloads under windy conditions. Mech. Syst. Signal Process. 2016, 72, 409–419. [Google Scholar] [CrossRef] [Scilit]
- Bello, M.M.; Mohamed, Z.; Efe, M.Ö.; Ishak, H. Modelling and dynamic characterisation of a double-pendulum overhead crane carrying a distributed-mass payload. Simul. Model. Pract. Theory 2024, 134, 102953. [Google Scholar] [CrossRef] [Scilit]
- Huang, J.; Liang, Z.; Zang, Q. Dynamics and swing control of double-pendulum bridge cranes with distributed-mass beams. Mech. Syst. Signal Process. 2015, 54, 357–366. [Google Scholar] [CrossRef] [Scilit]
- Ye, J.; Huang, J. Control of beam-pendulum dynamics in a tower crane with a slender jib transporting a distributed-mass load. IEEE Trans. Ind. Electron. 2022, 70, 888–897. [Google Scholar] [CrossRef] [Scilit]
- Wu, Q.; Sun, N.; Yang, T.; Fang, Y. Deep reinforcement learning-based control for asynchronous motor-actuated triple pendulum crane systems with distributed mass payloads. IEEE Trans. Ind. Electron. 2023, 71, 1853–1862. [Google Scholar] [CrossRef] [Scilit]
- Yang, L.; Ouyang, H. Precision-positioning adaptive controller for swing elimination in three-dimensional overhead cranes with distributed mass beams. ISA Trans. 2022, 127, 449–460. [Google Scholar] [CrossRef] [Scilit]
- Yu, S.; Yu, X.; Shirinzadeh, B.; Man, Z. Continuous finite-time control for robotic manipulators with terminal sliding mode. Automatica 2005, 41, 1957–1964. [Google Scholar] [CrossRef] [Scilit]
- McCue, L. Handbook of marine craft hydrodynamics and motion control. IEEE Control Syst. Mag. 2016, 36, 78–79. [Google Scholar]
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2025 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).