Design and Performance Analysis of an XY Precision Motion Platform with Decoupling Based on Connecting Arm and Guide Rail Integration

 ,

Abstract
1. Introduction
2. Overall Platform Structure Analysis
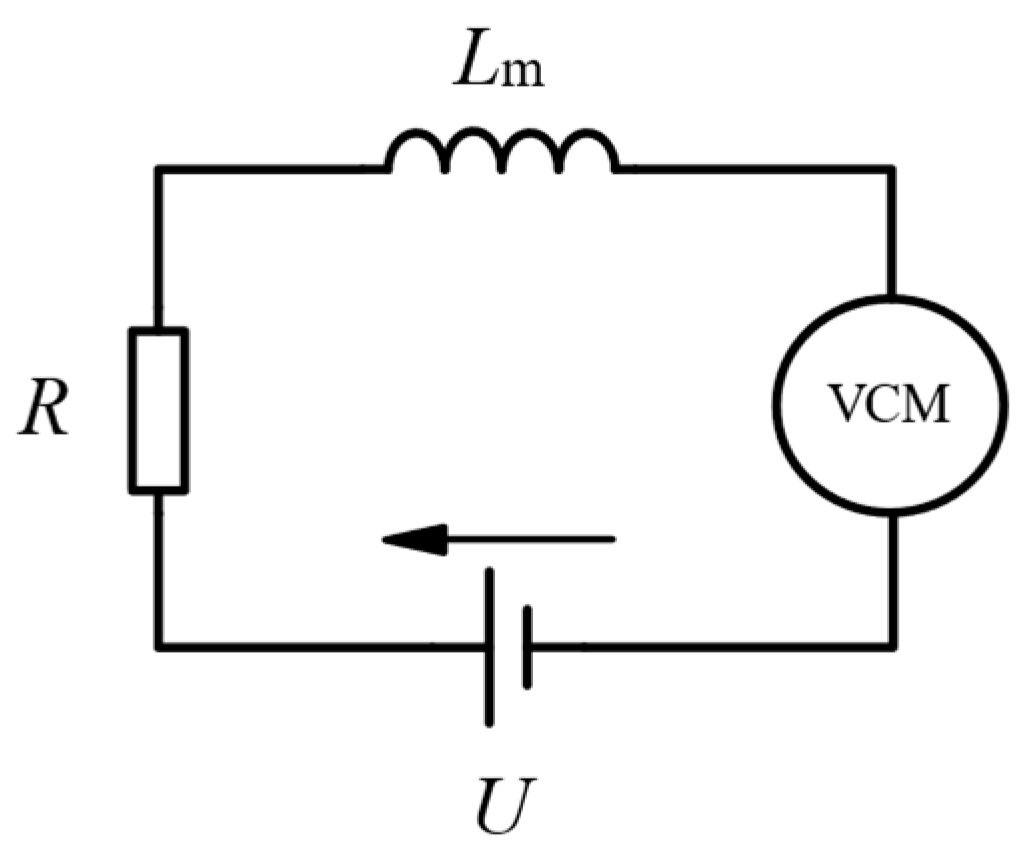
2.1. Voice Coil Motor (Actuation) Analysis
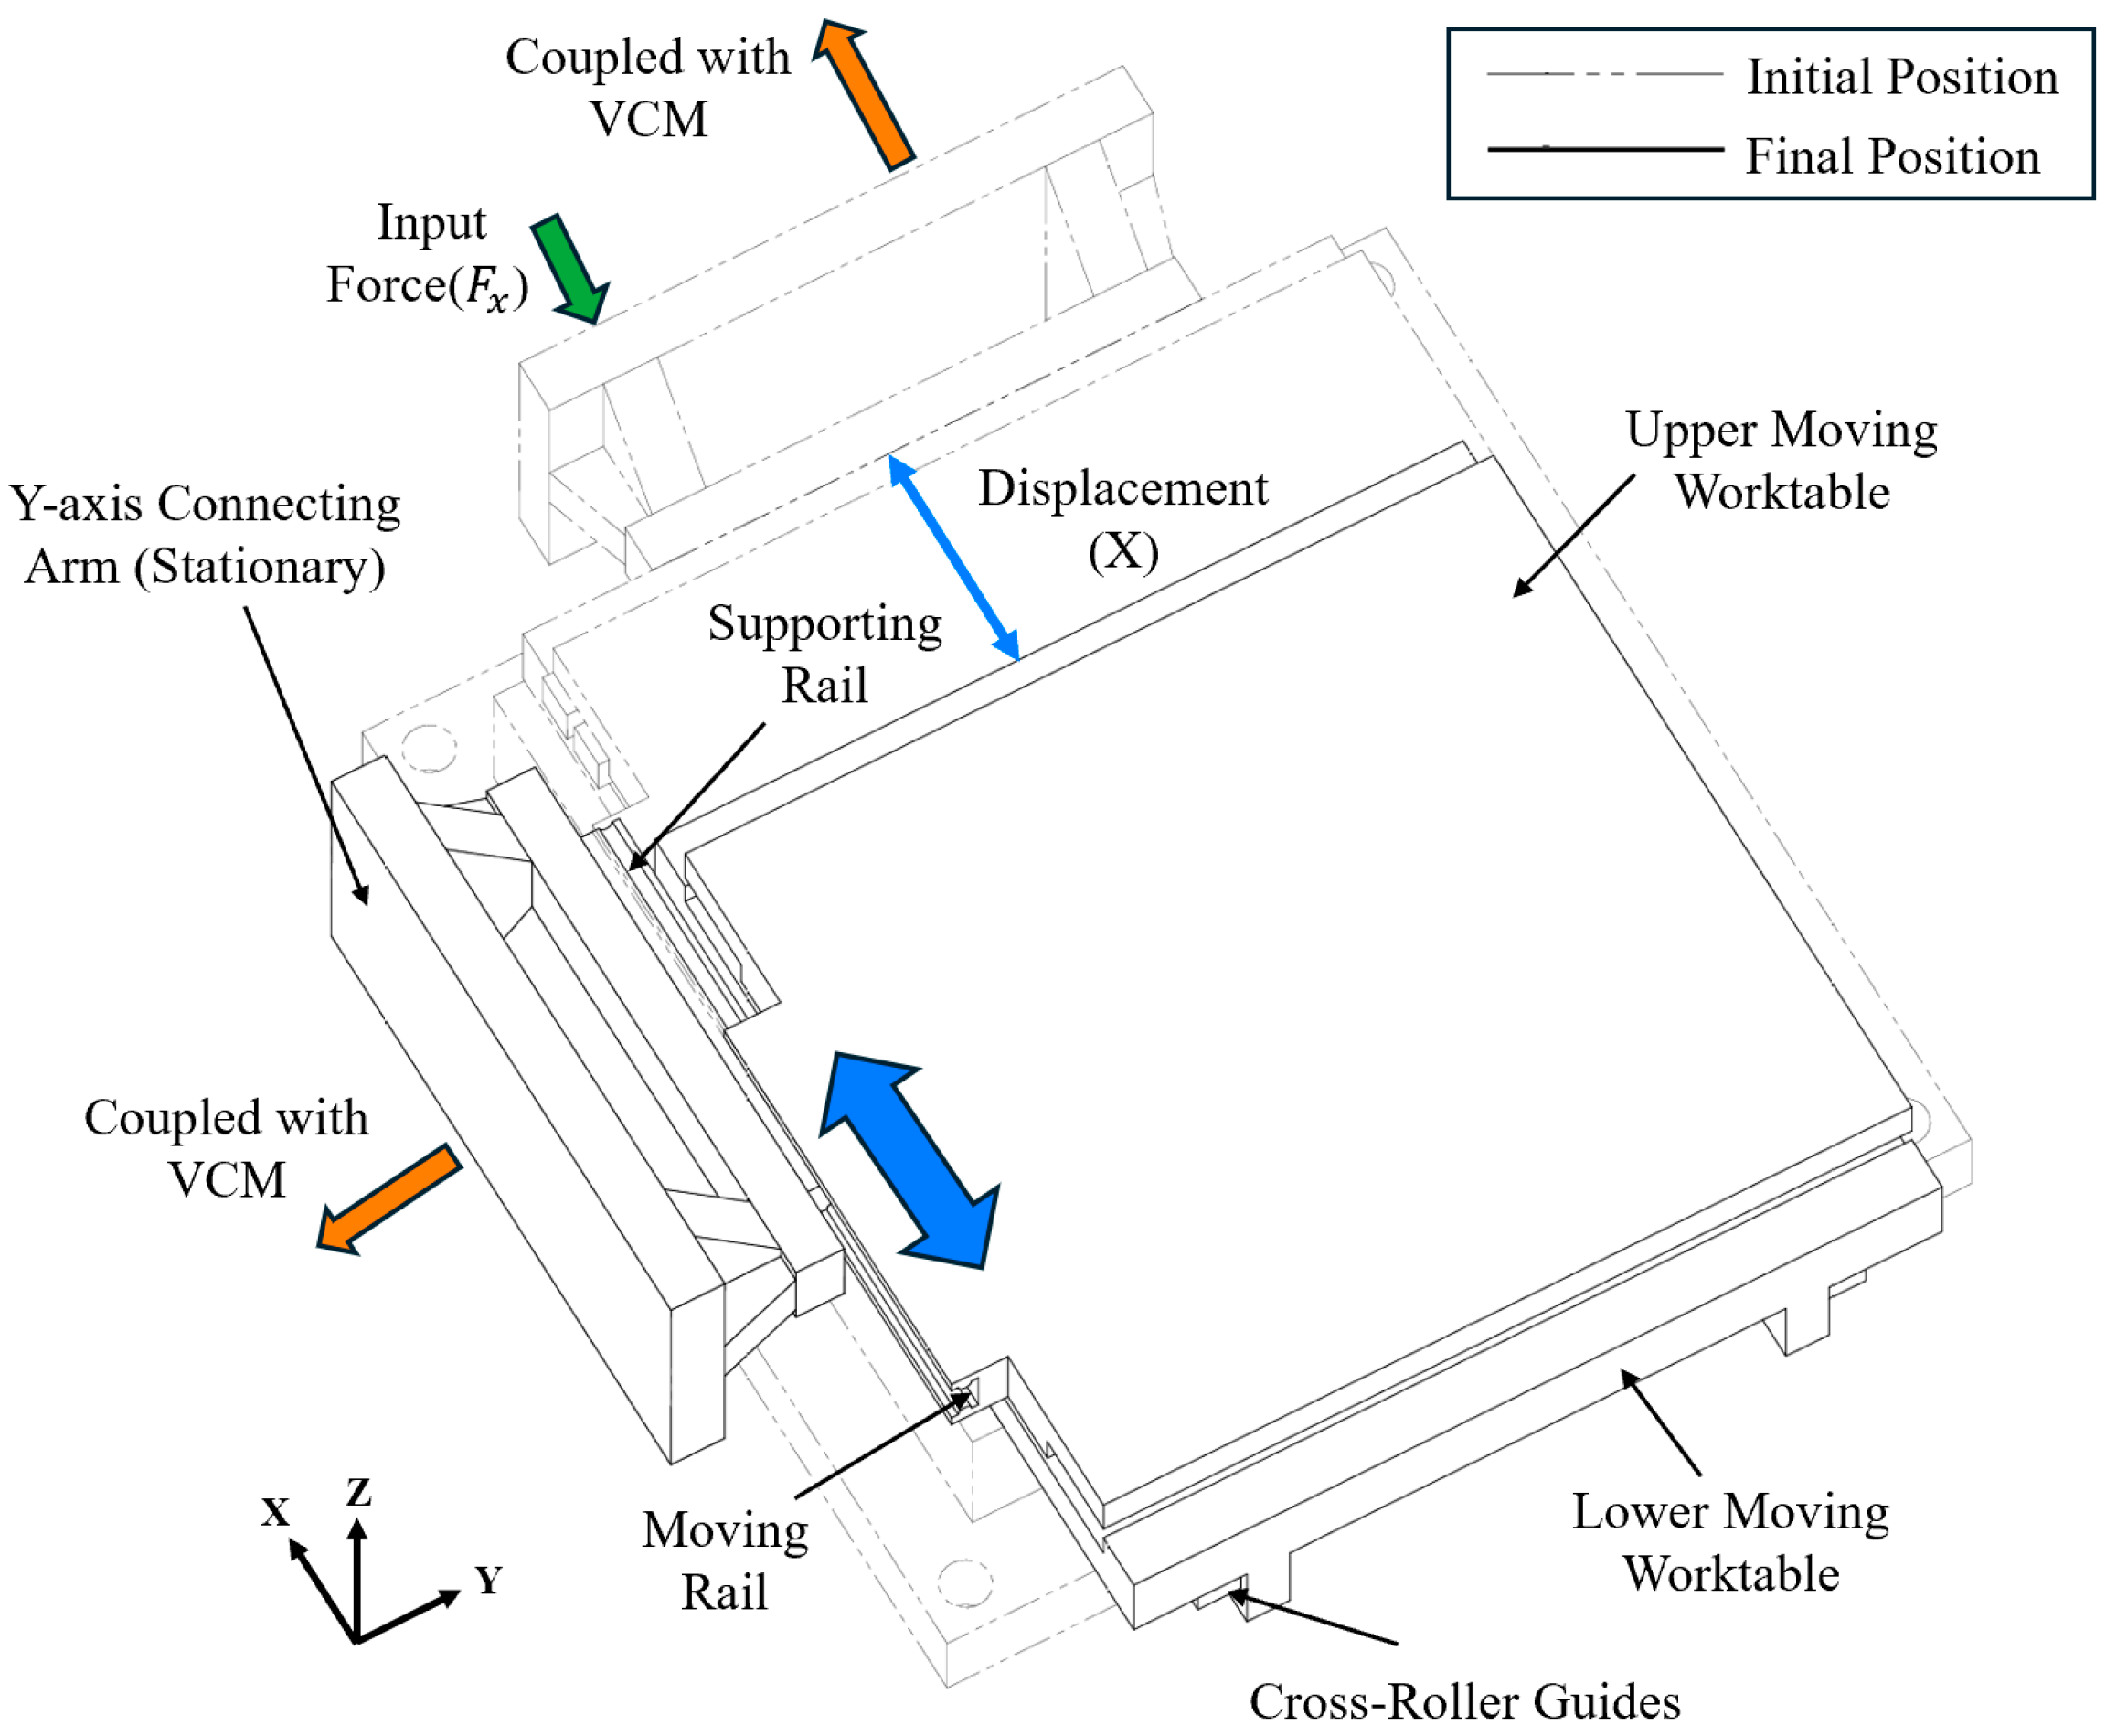
2.2. Platform Structure Analysis
2.3. Decoupling Principle and Comparative Analysis
3. Finite Element Analysis of the Platform
3.1. Static Analysis
3.2. Modal Analysis
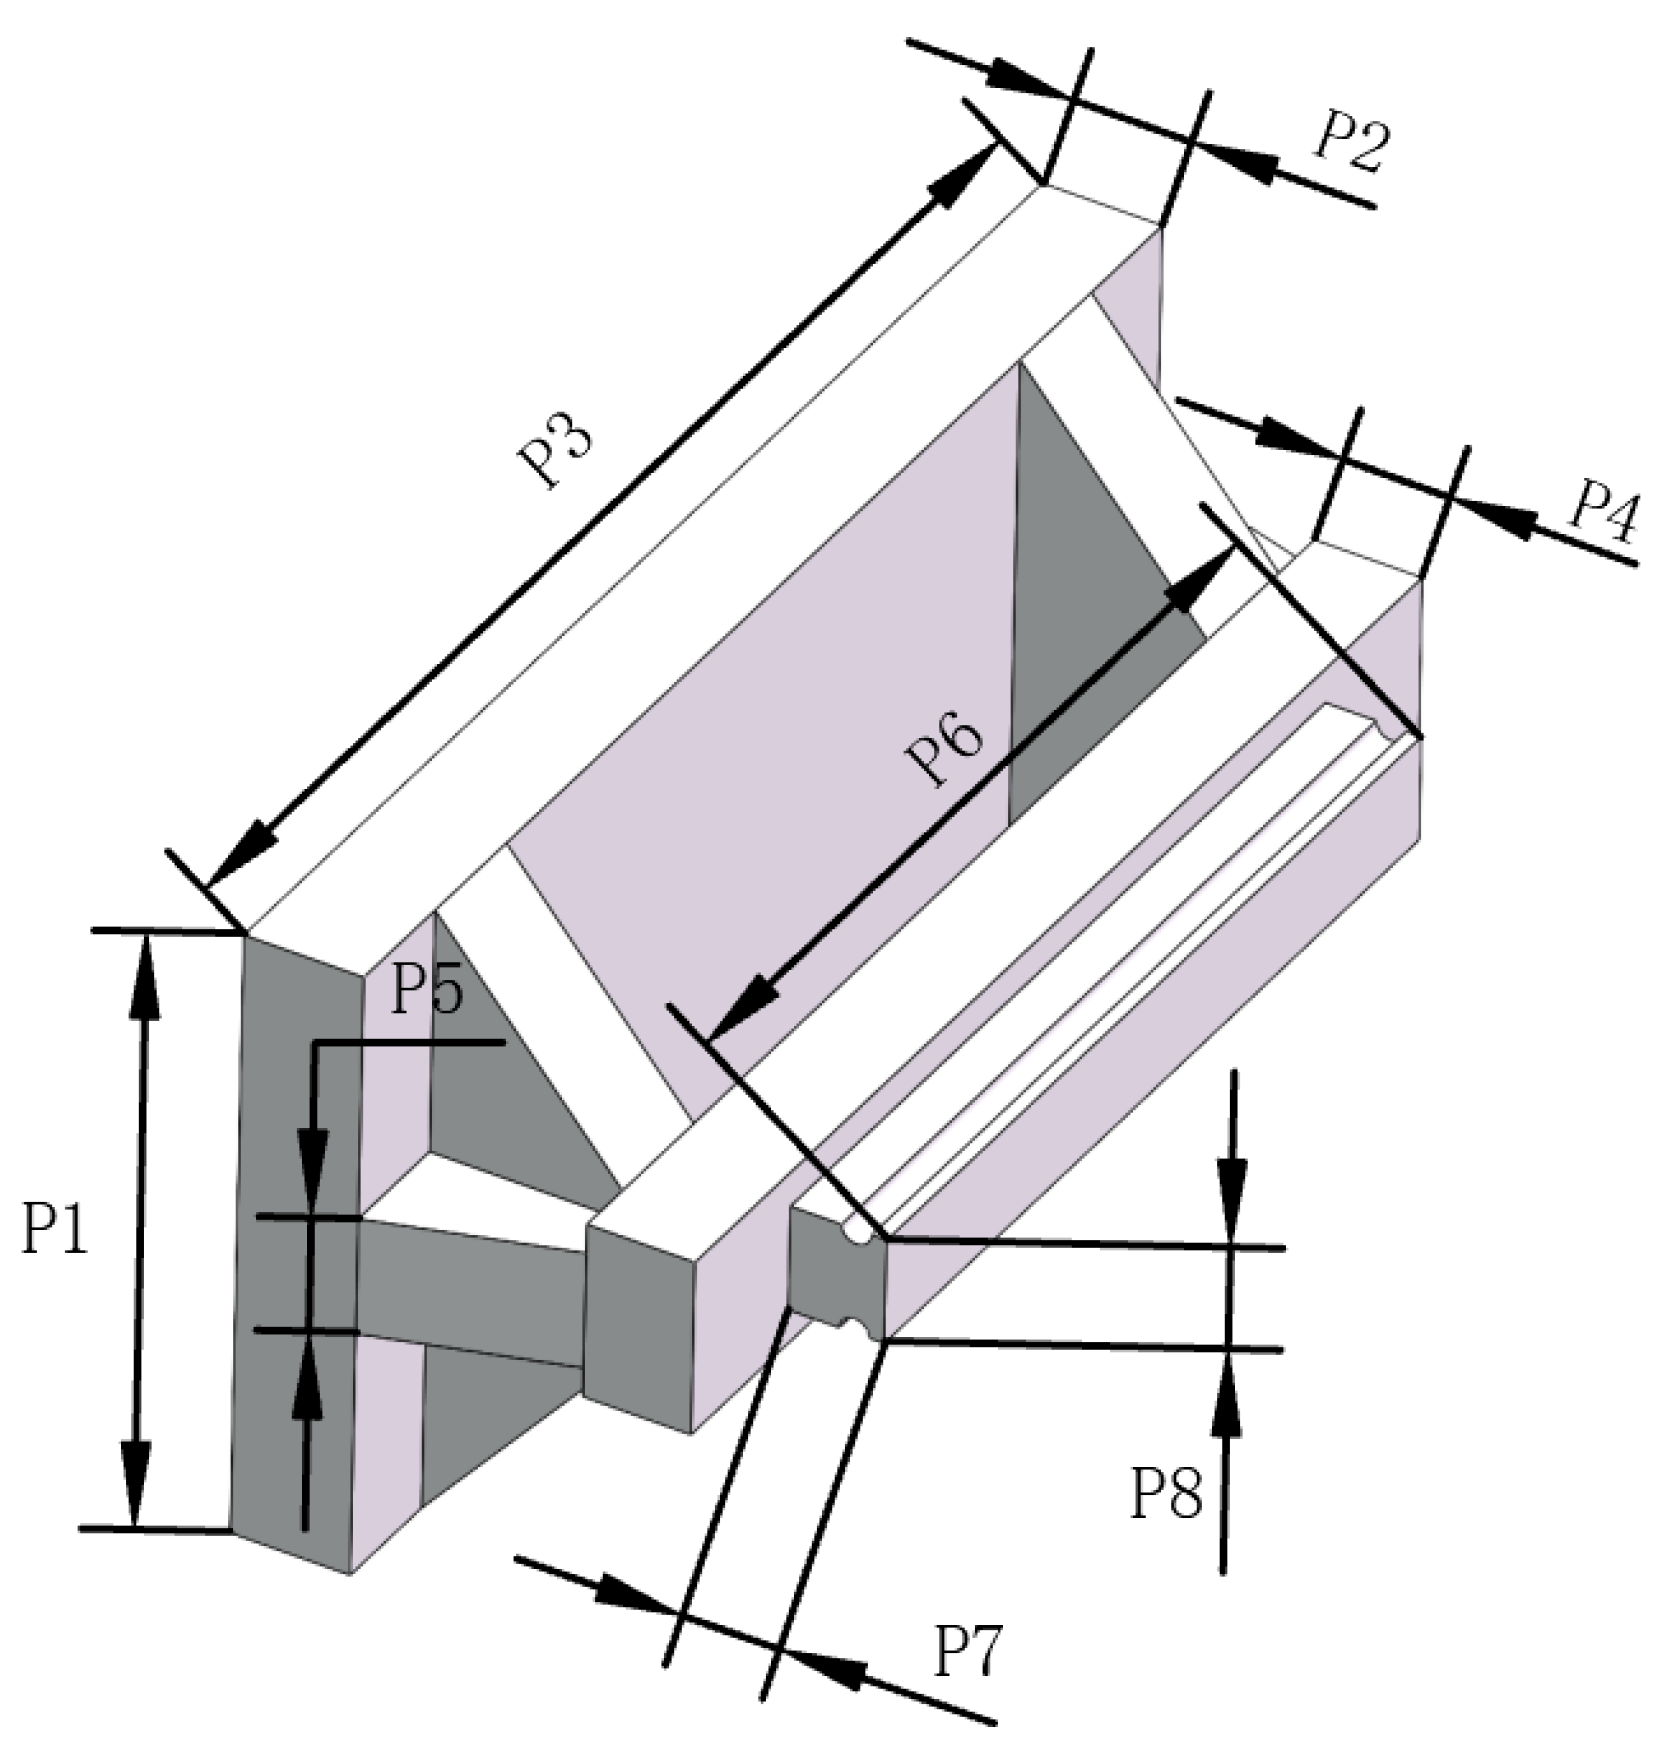
3.3. Parametric Optimization of the Connecting Arm
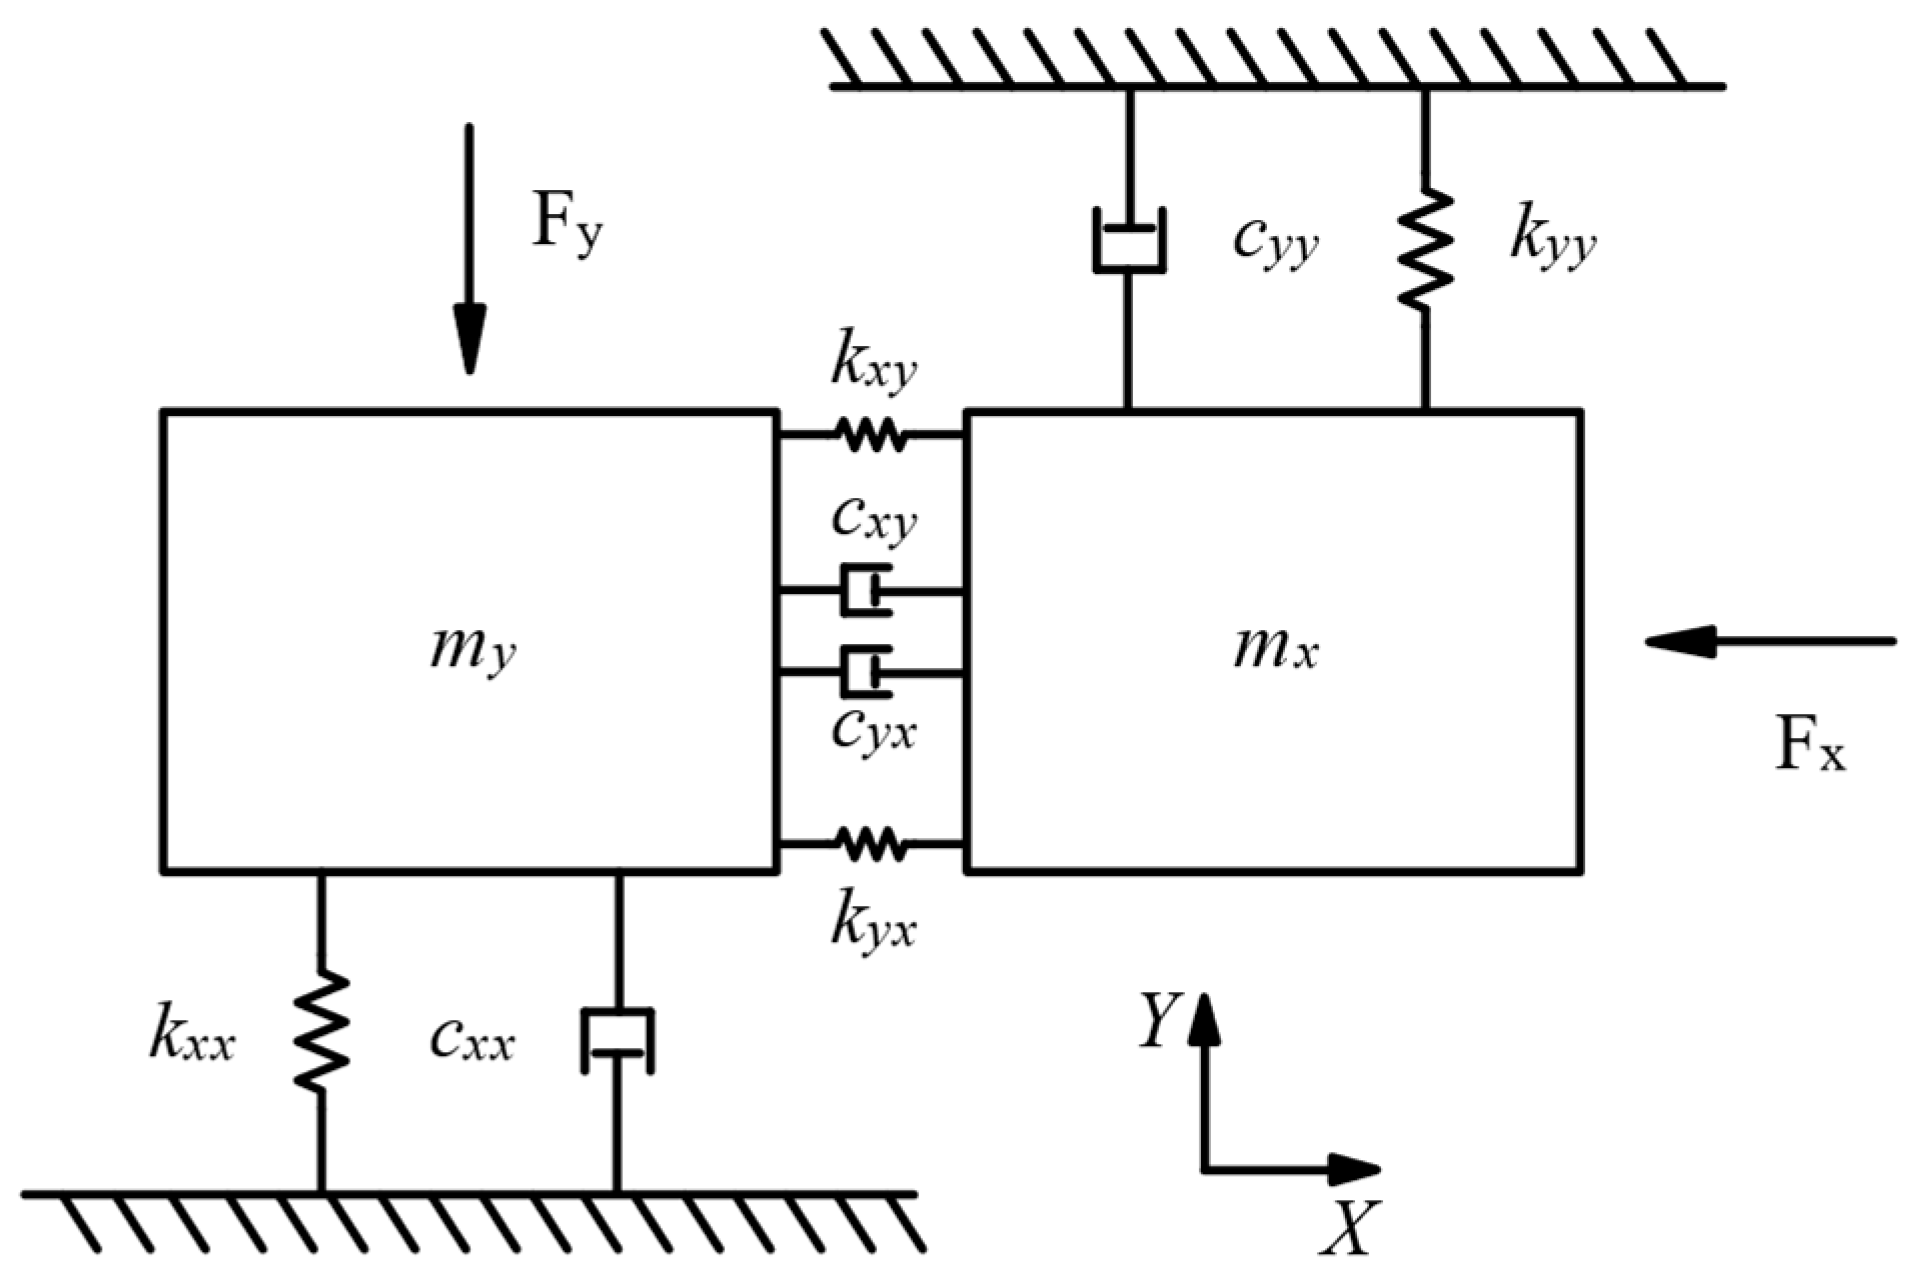
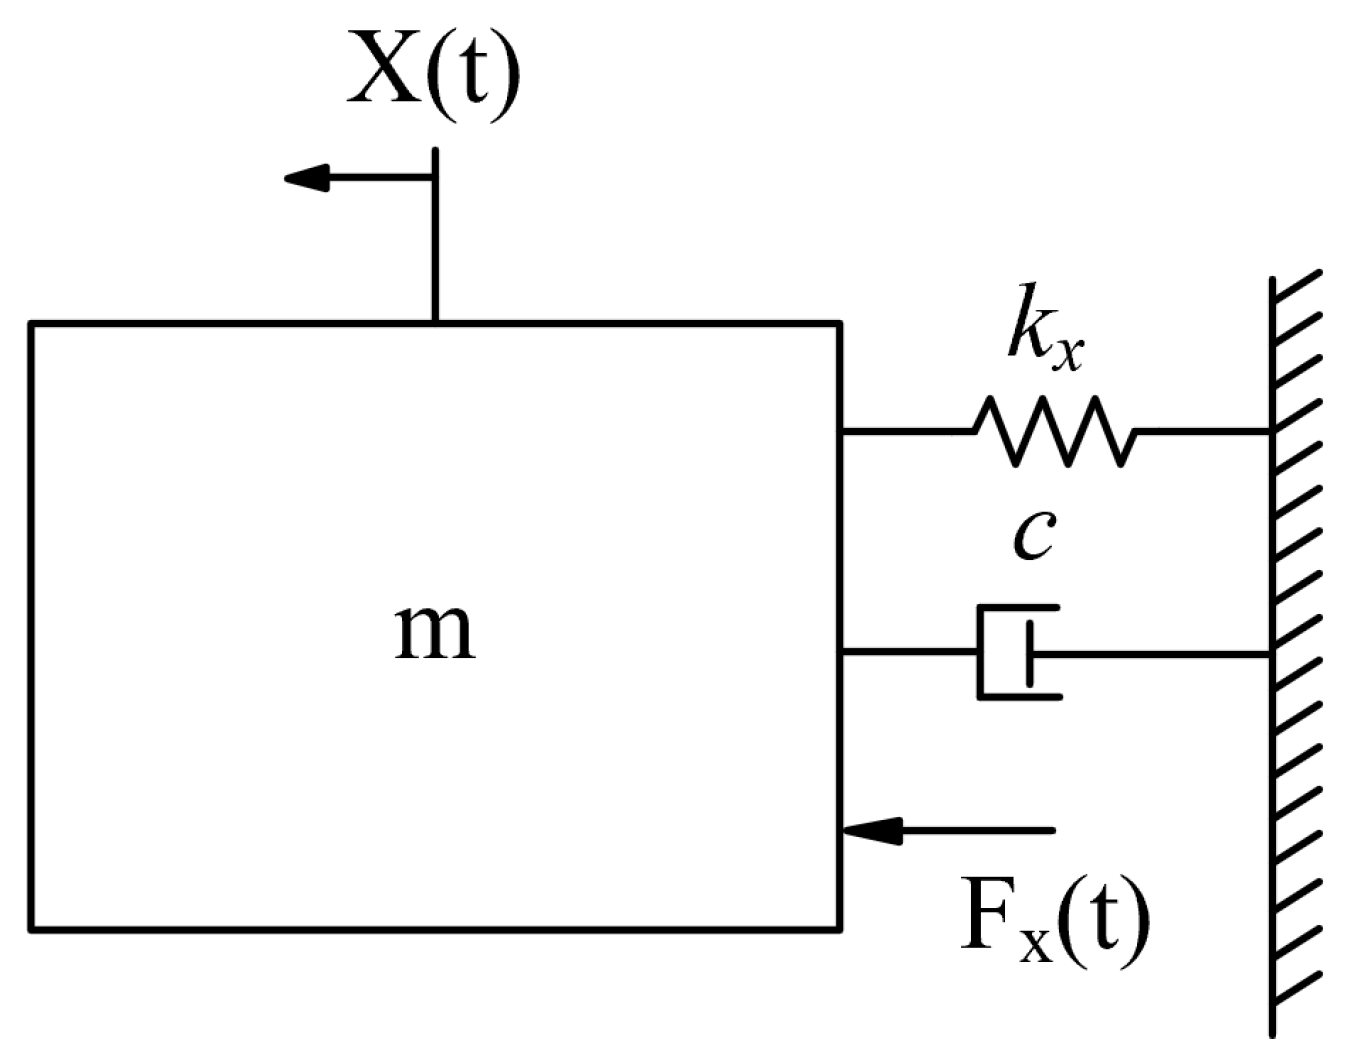
3.4. Dynamic Performance Analysis
4. Experimental Measurement and Results
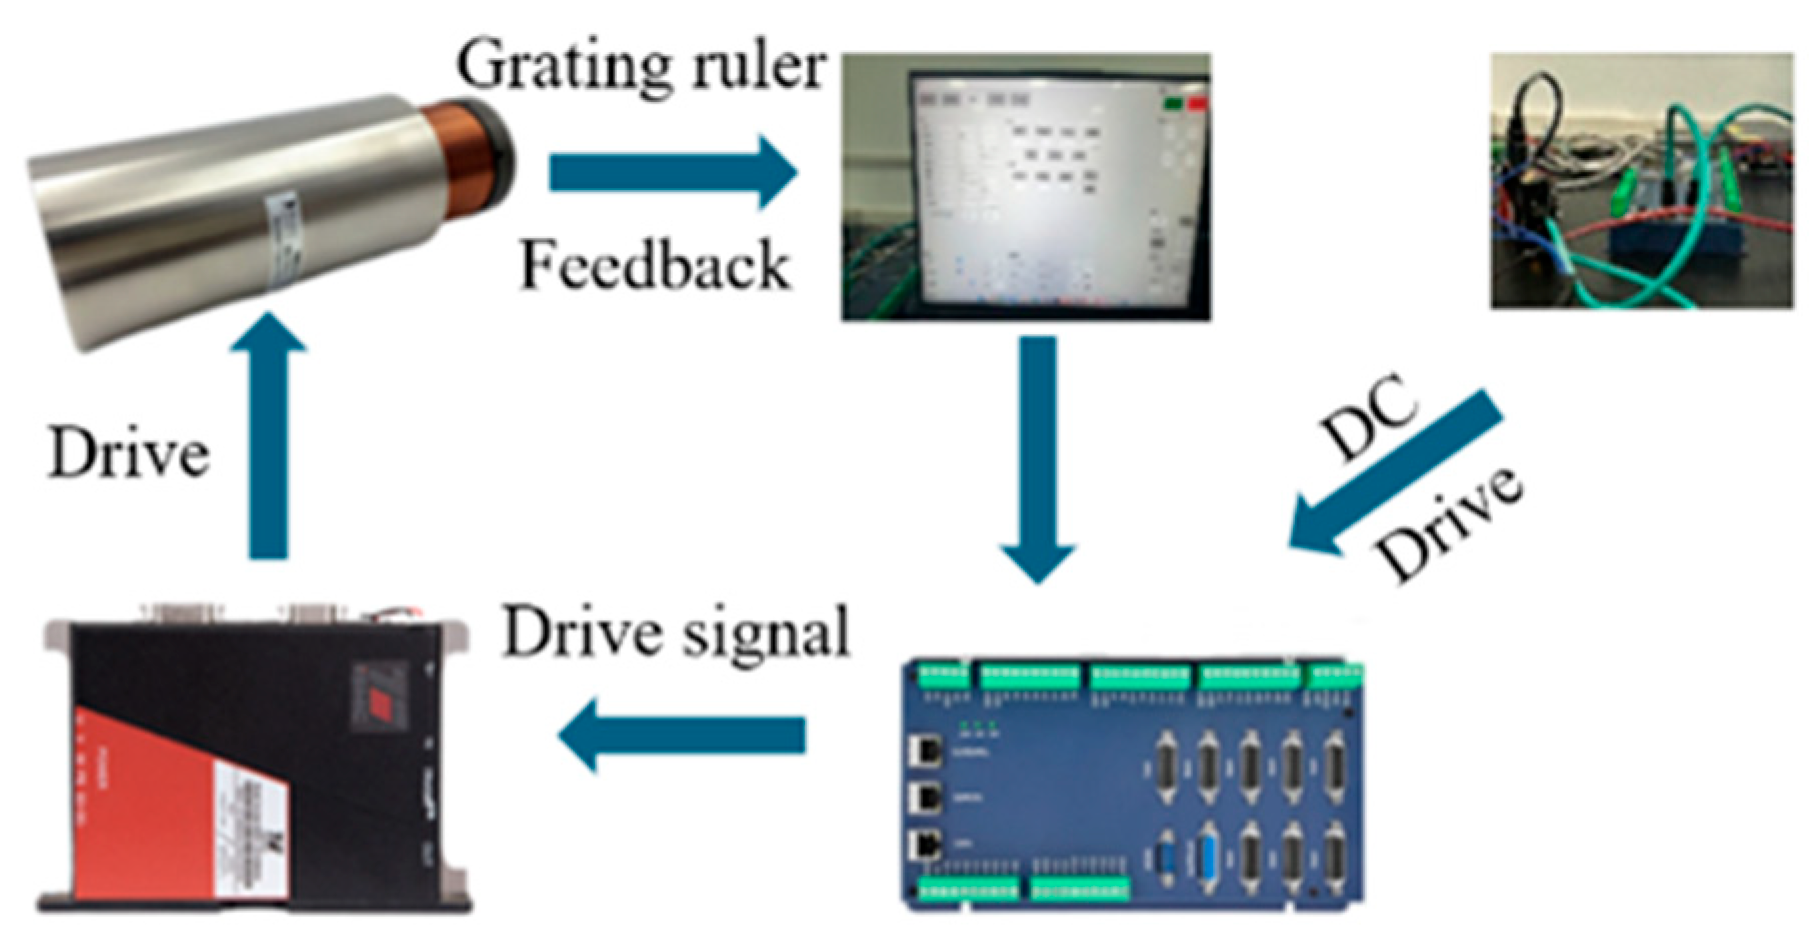
4.1. Experimental Platform Setup
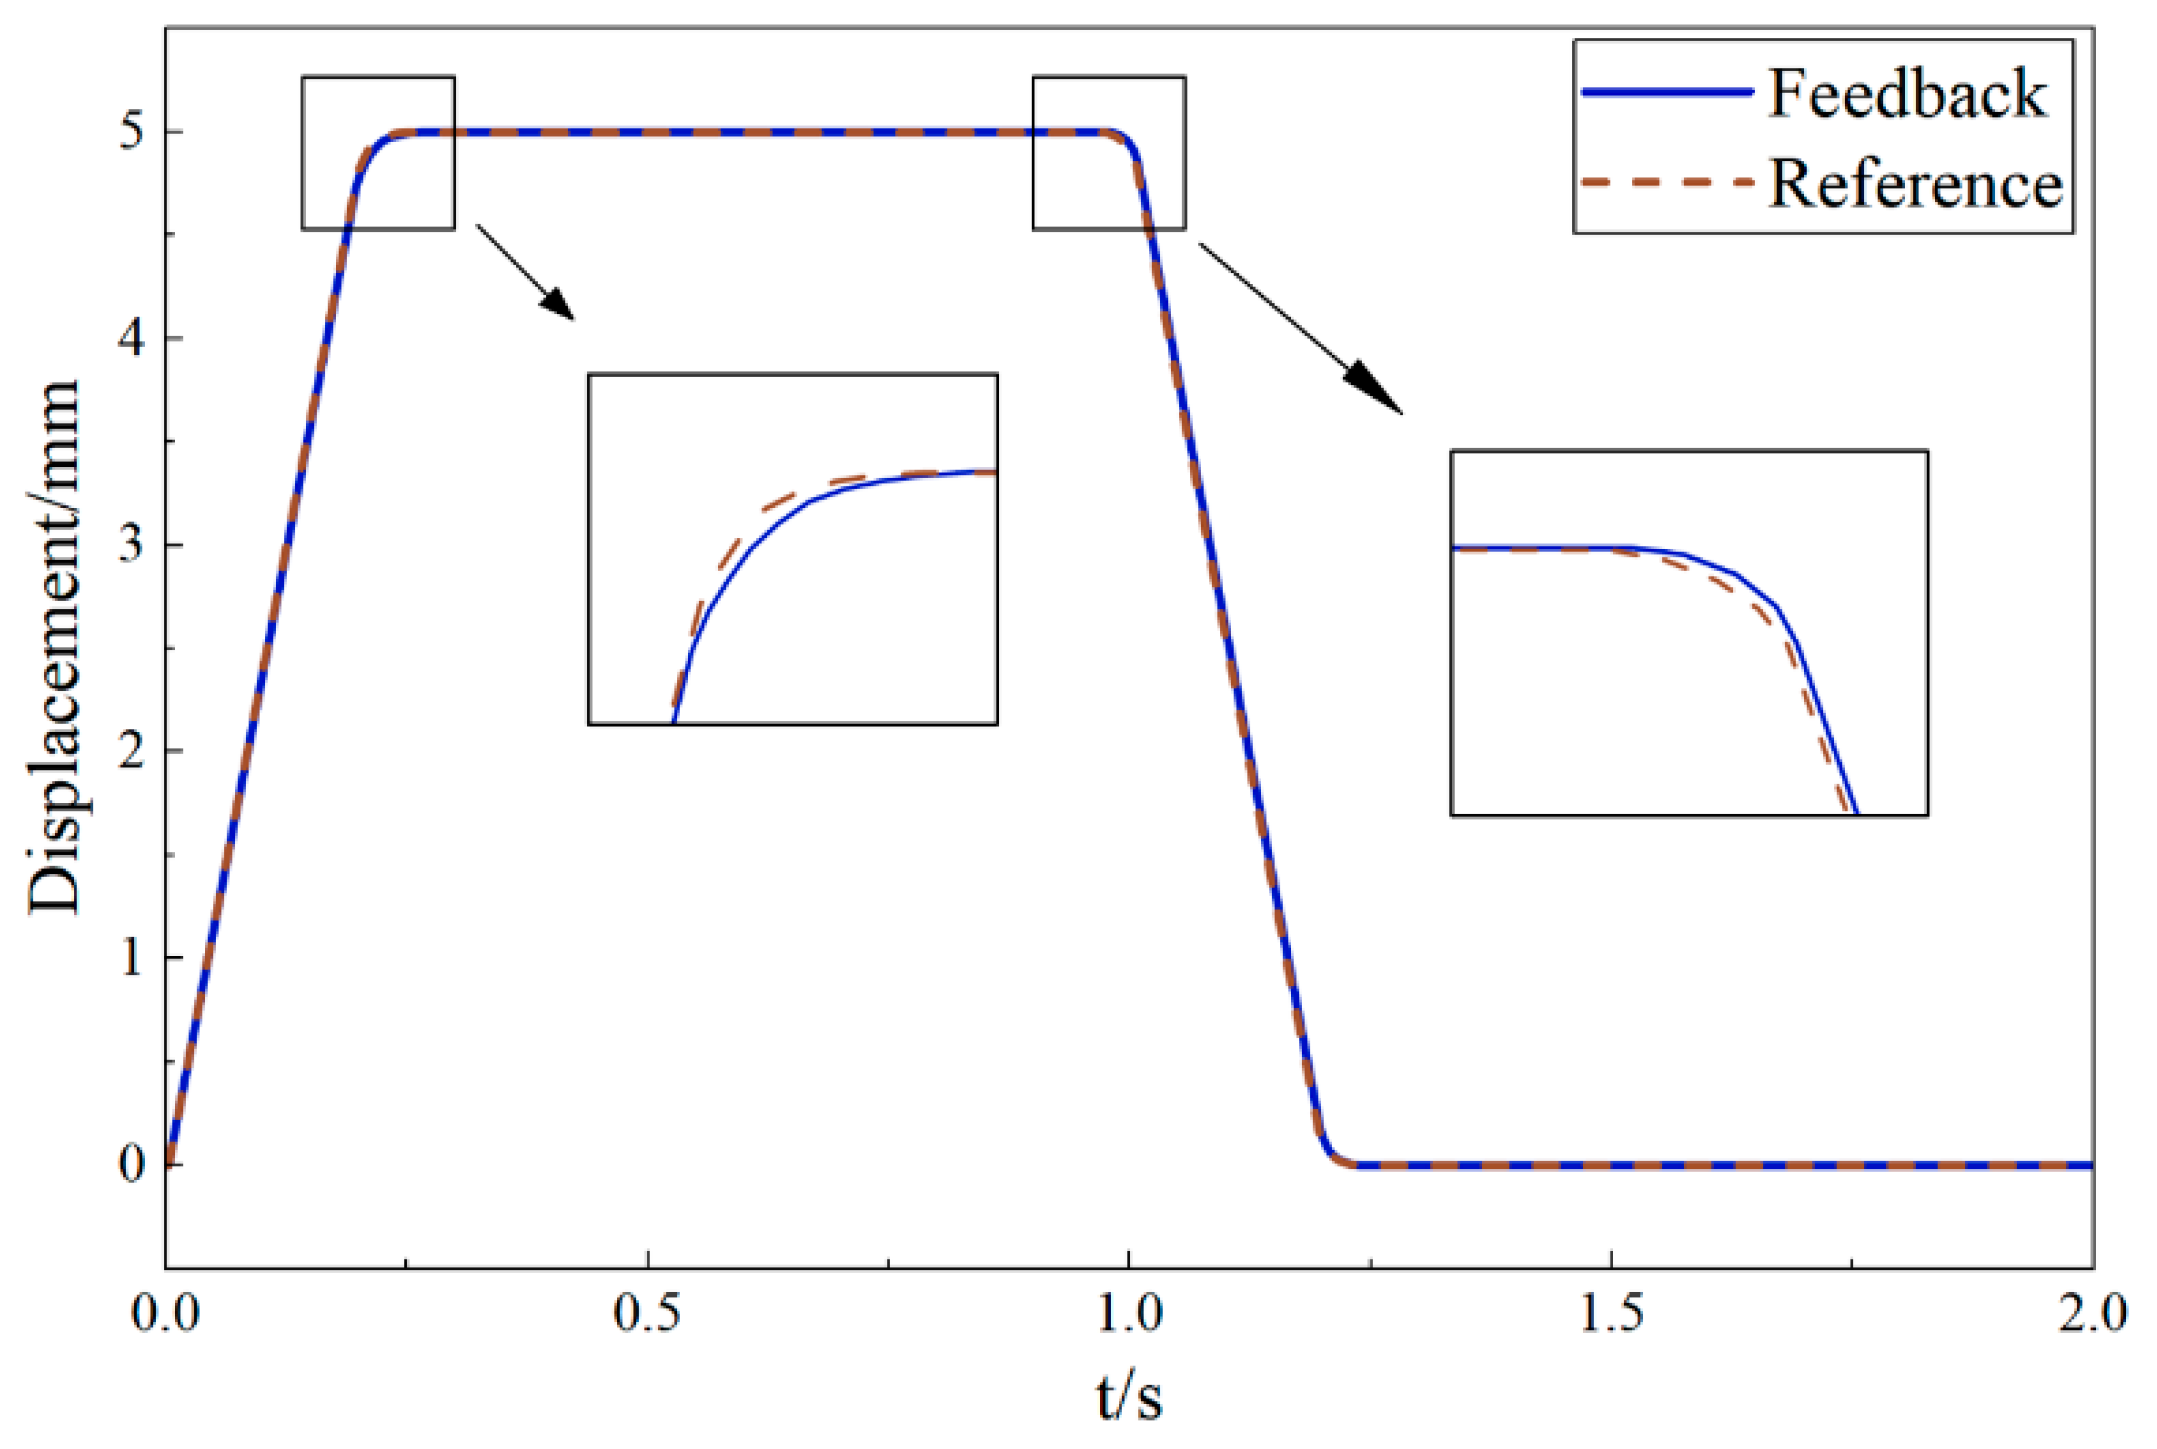
4.2. Experimental Measurement
5. Conclusions
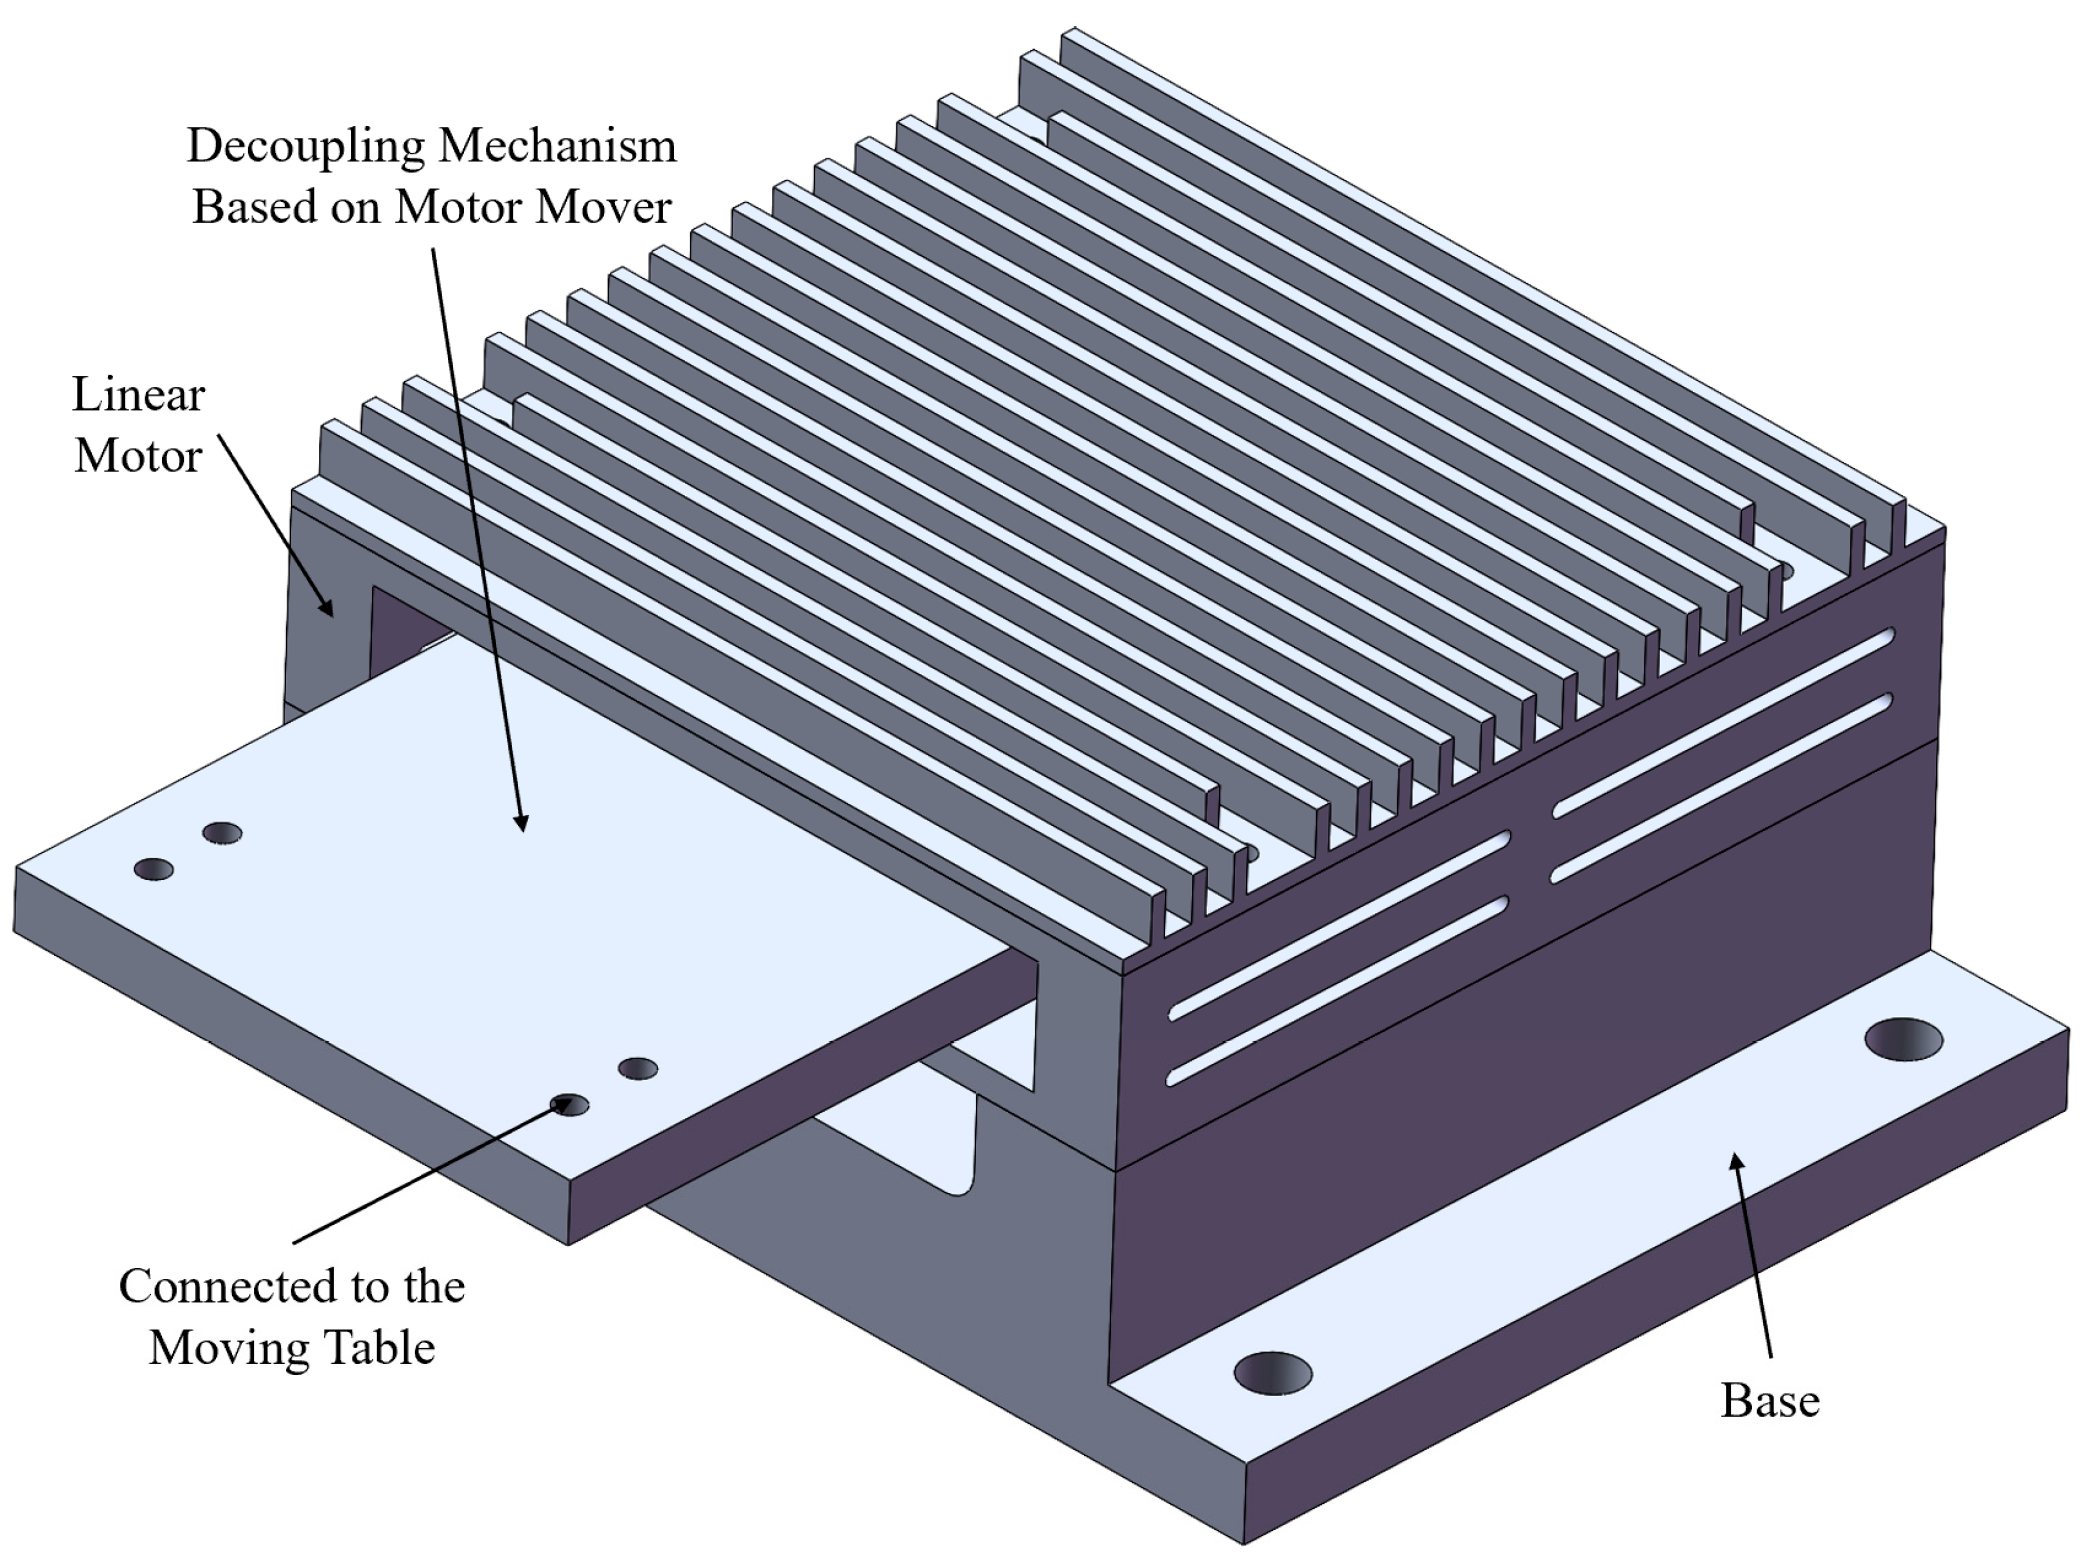
- Proposed Decoupling Mechanism and Comparative Advantages: The designed structure integrates the motion decoupling function directly into the rigid connecting arm. Unlike traditional flexure-based mechanisms limited by micrometer-level strokes or mover-decoupling platforms that may compromise stiffness due to slender designs, this solution achieves a millimeter-level macro-stroke while maintaining a compact and high-stiffness assembly.
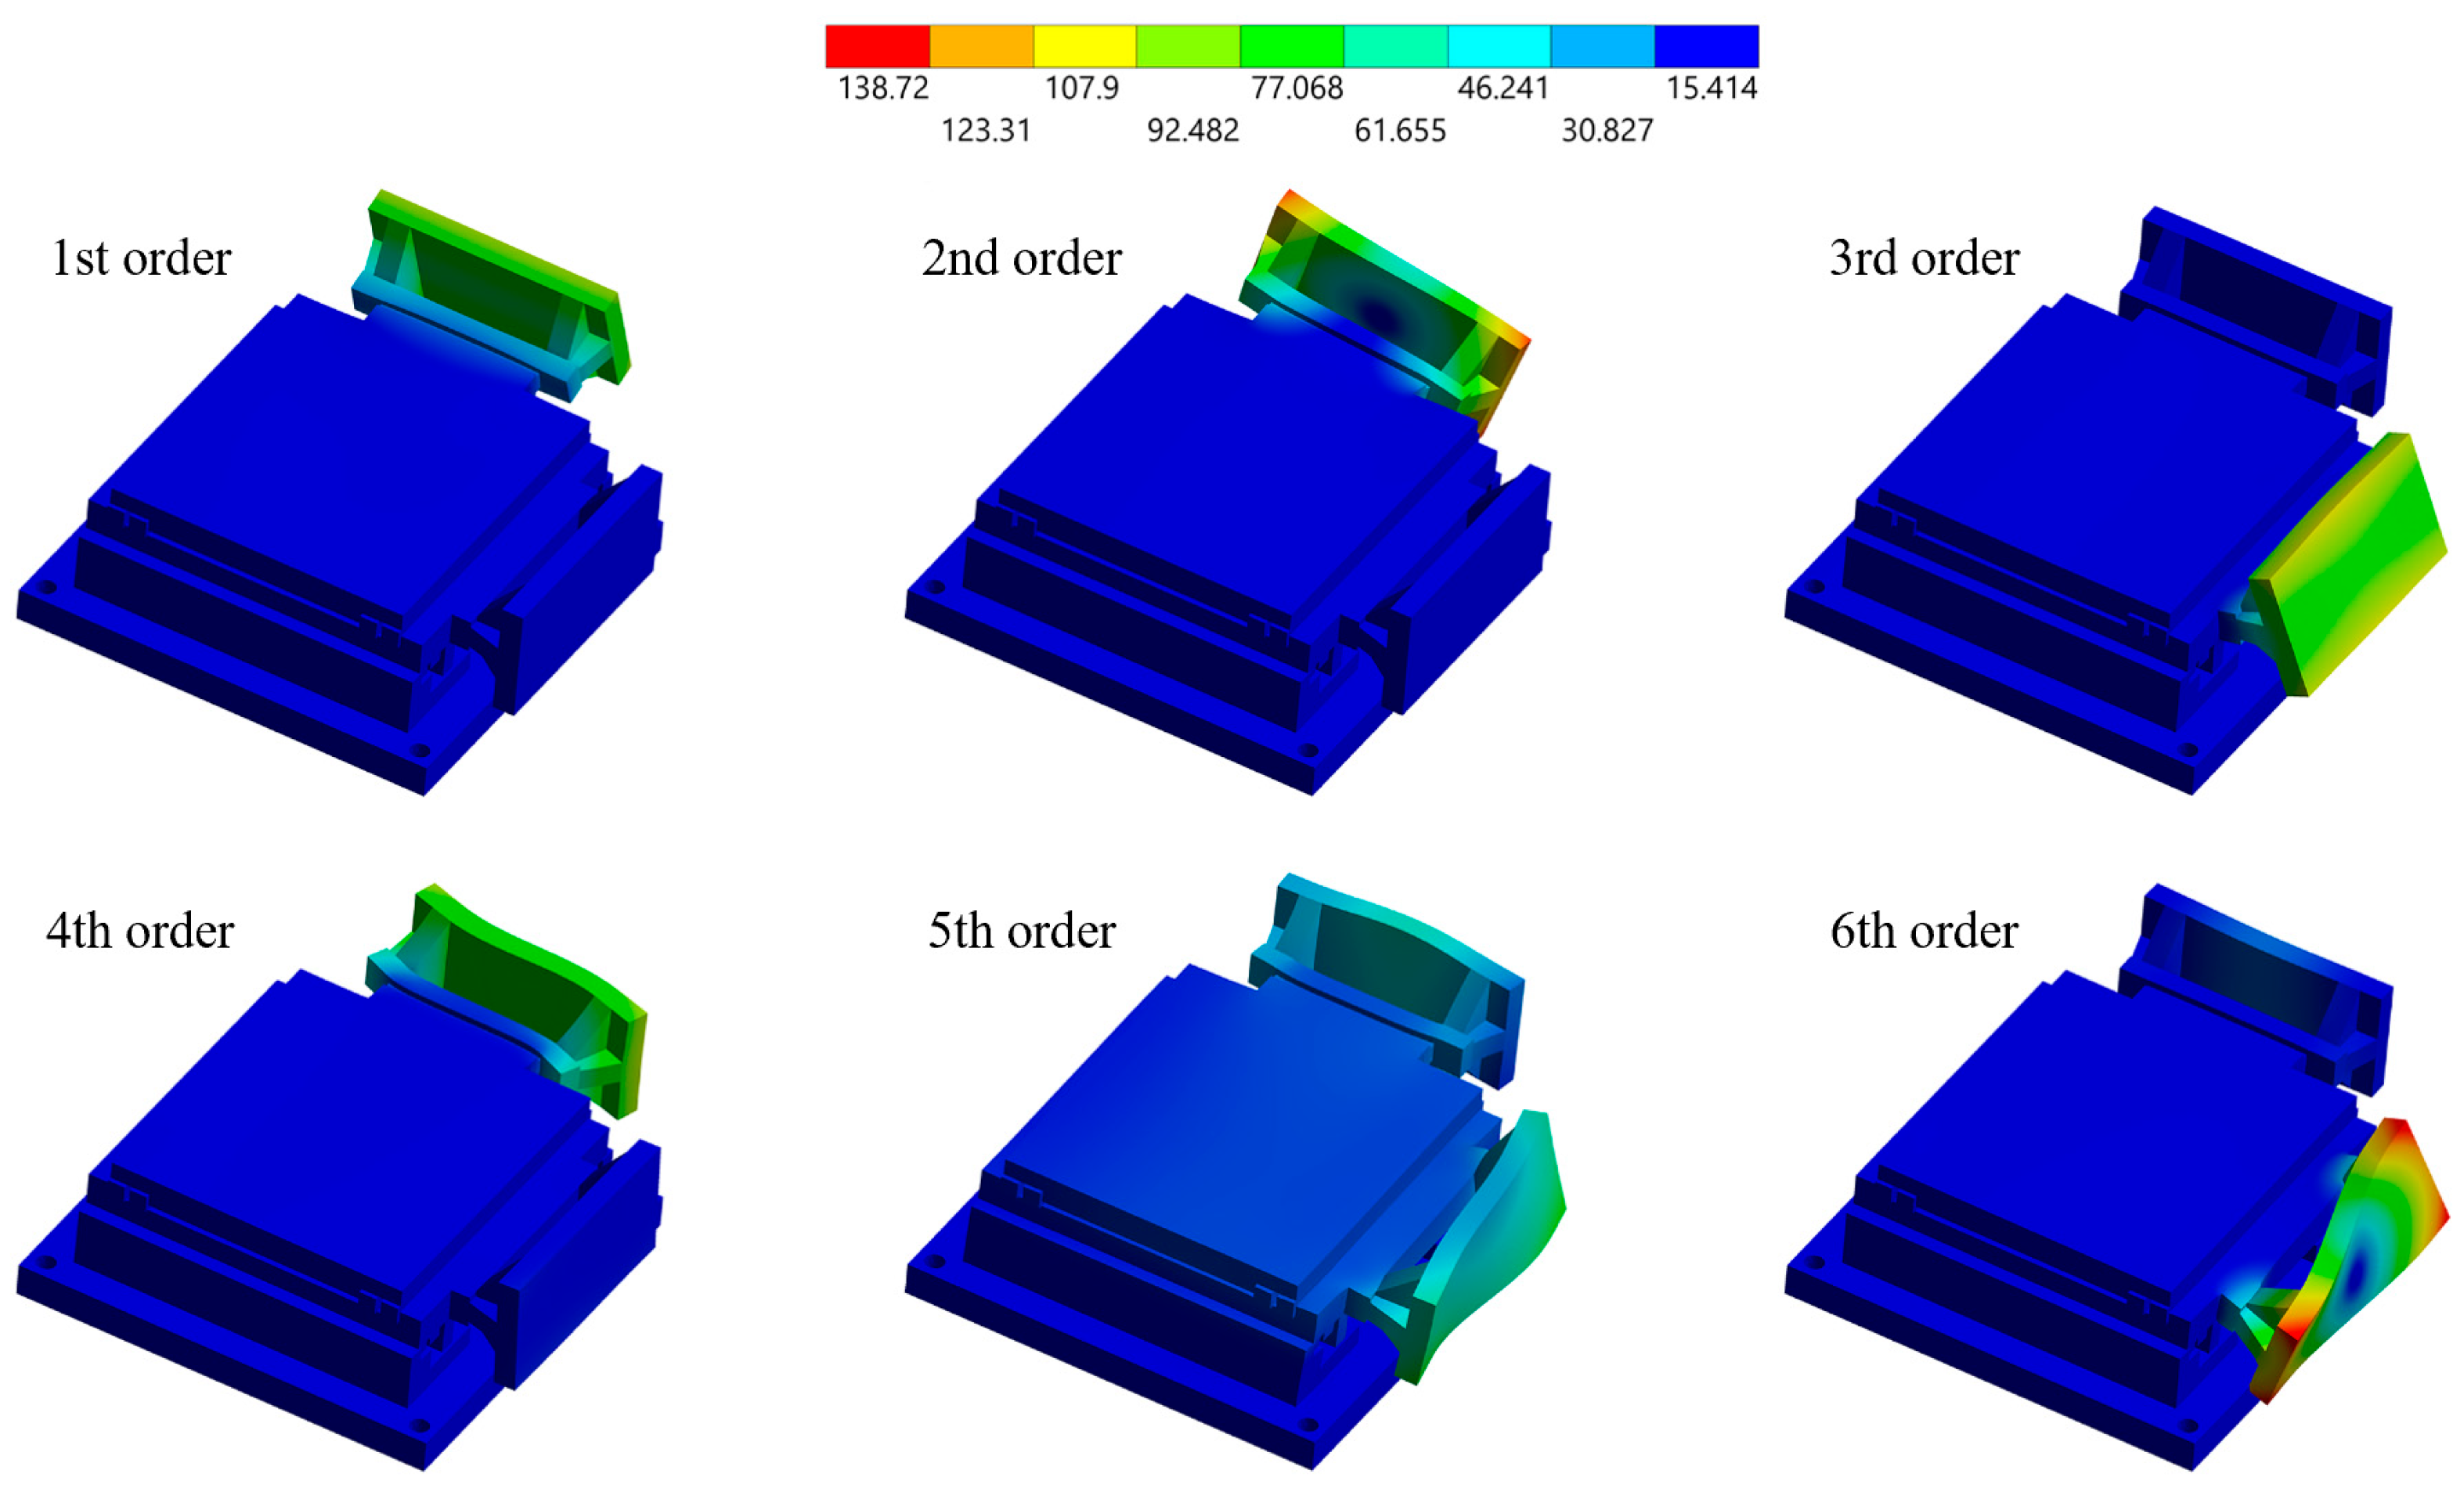
- Dynamic Performance and Resonance Mitigation: Quantitative results suggest that the first-order natural frequency of the proposed connecting arm reaches 1014 Hz, which is nearly double the 564.97 Hz reported for traditional motor-mover decoupling structures. The platform’s overall first-order frequency (864.82 Hz) is considerably higher than the VCM’s actuation frequency (89.35 Hz), which avoids low-frequency resonance and supports system stability under high-bandwidth control.
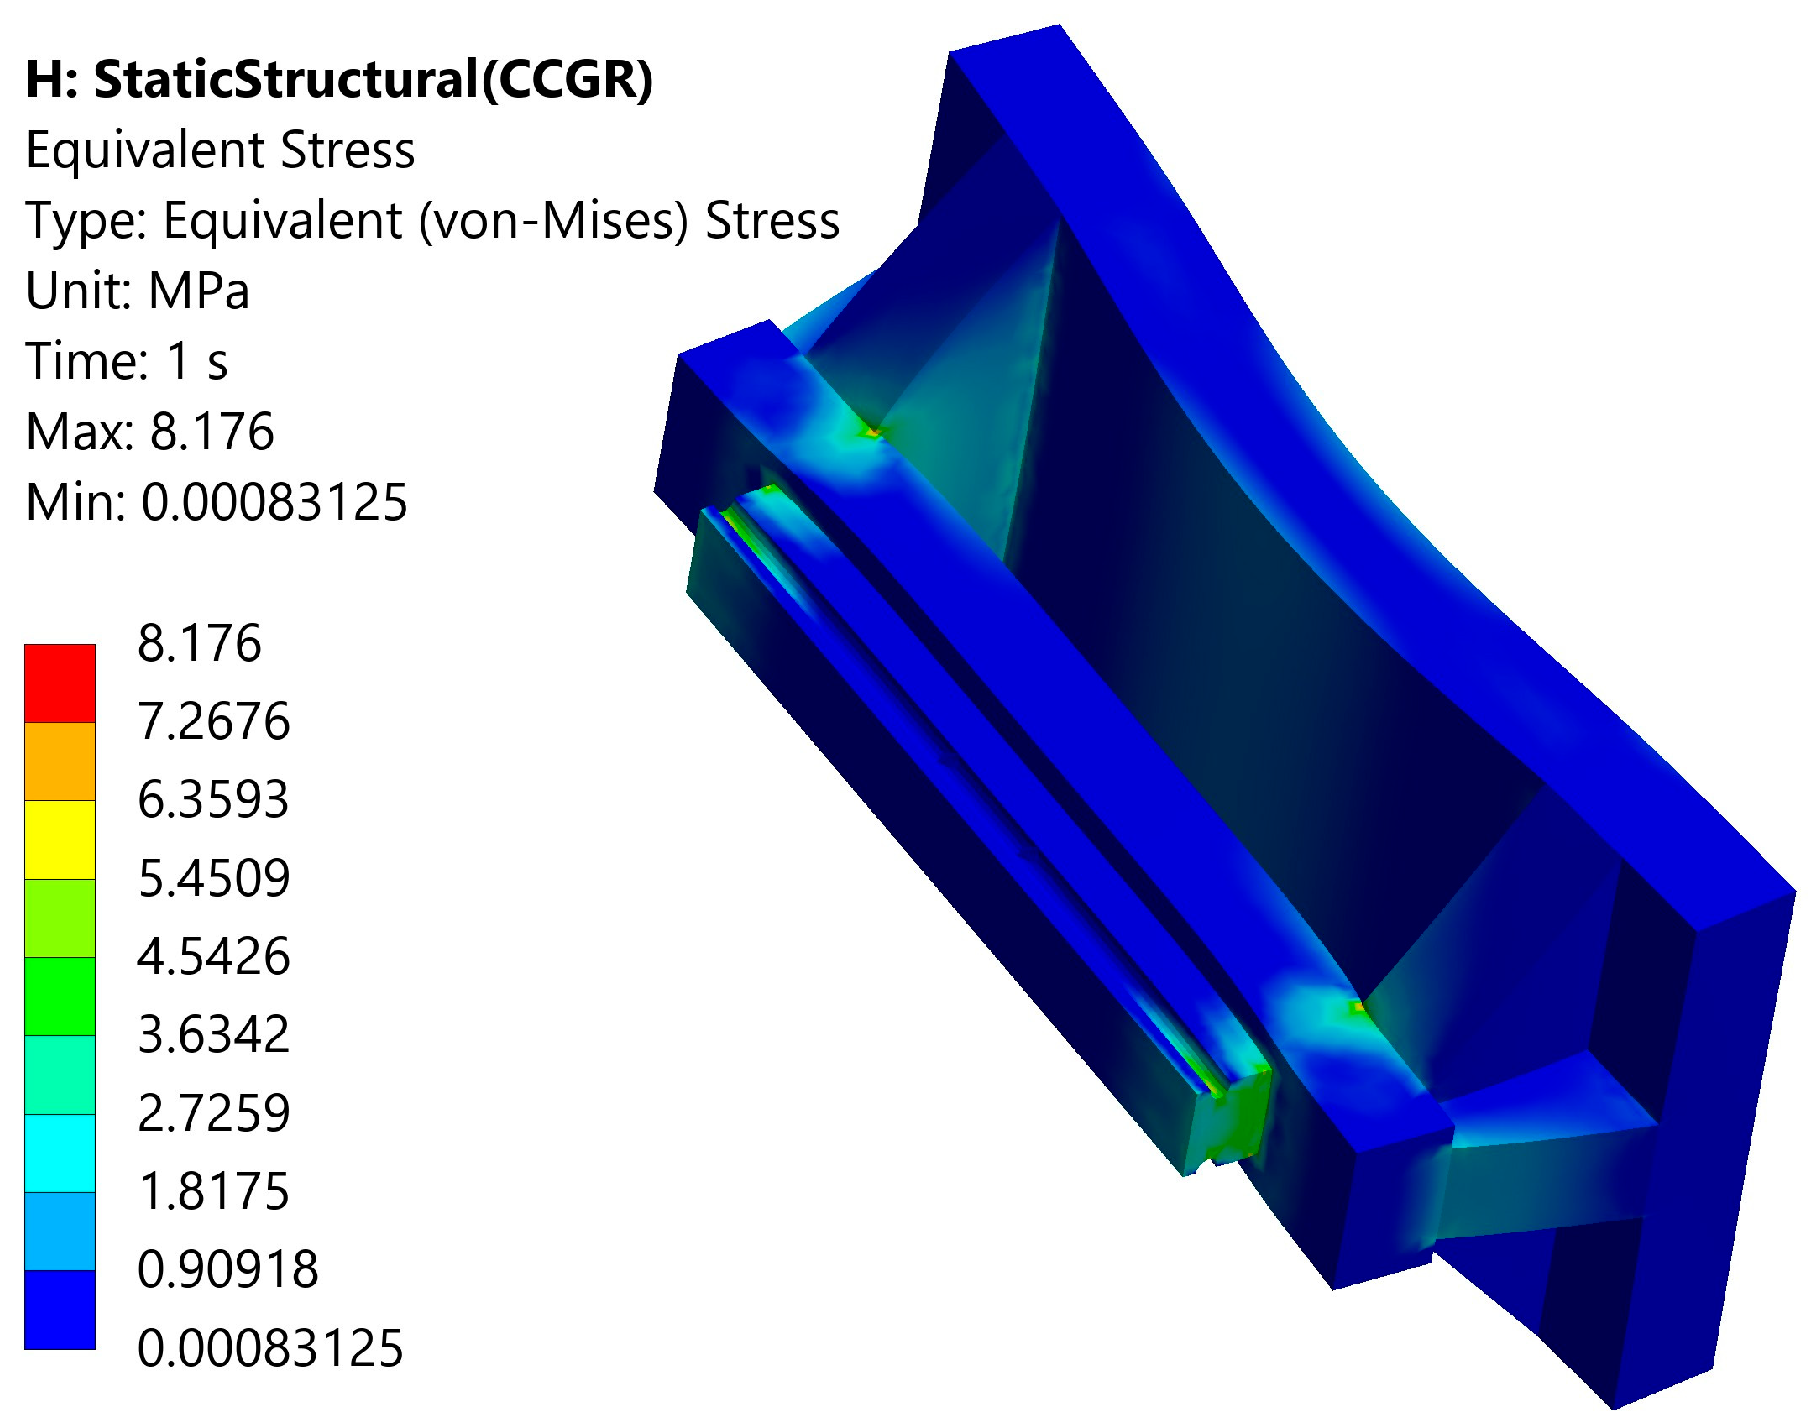
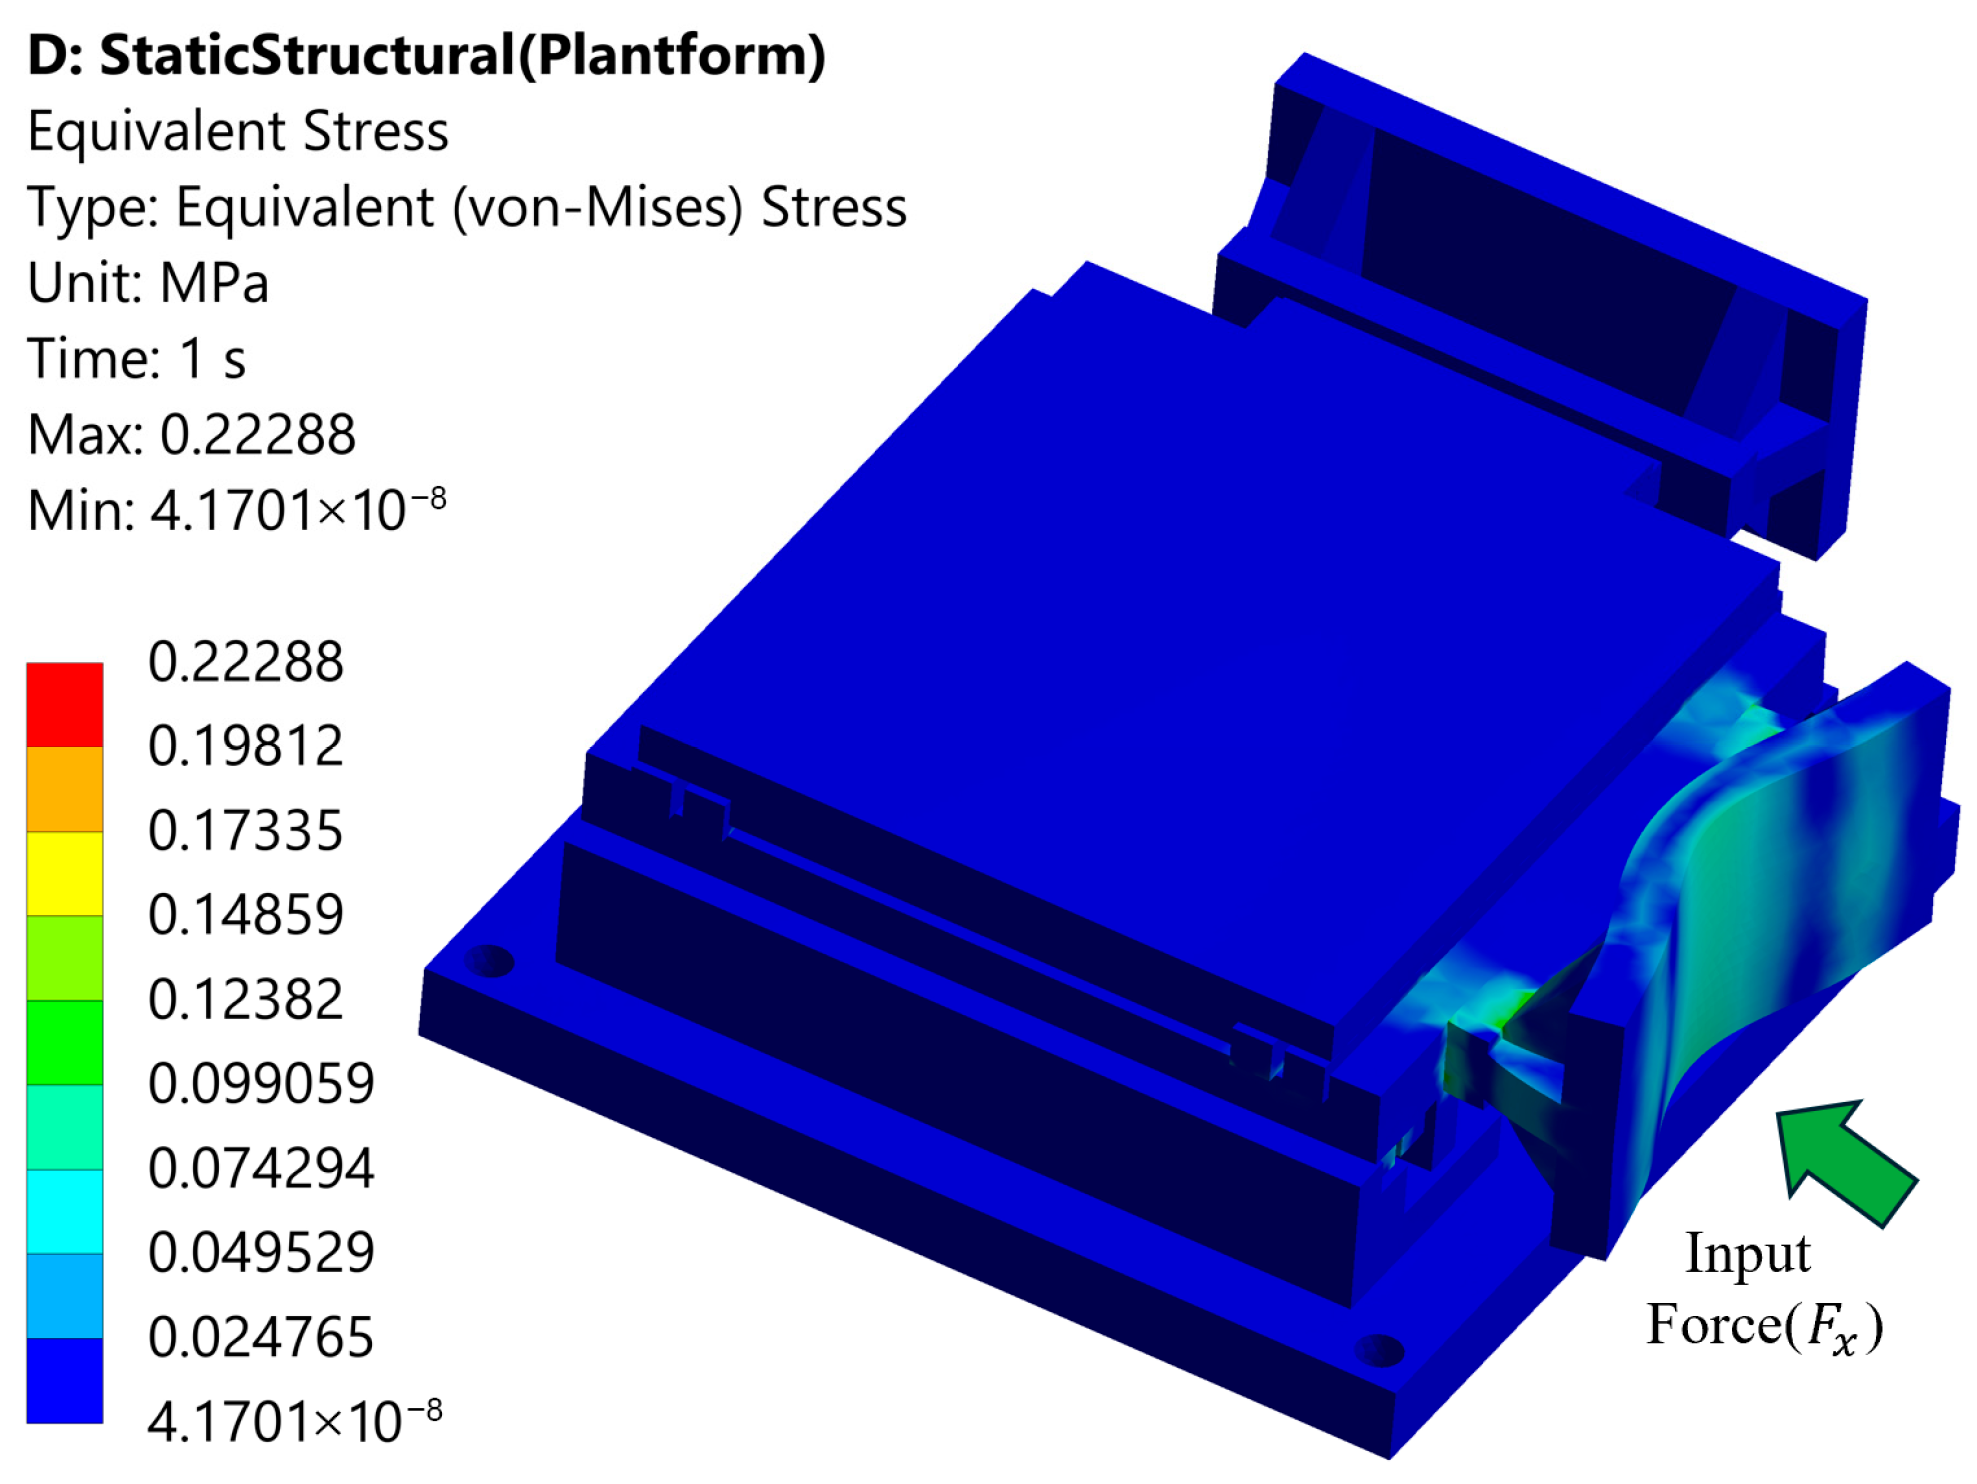
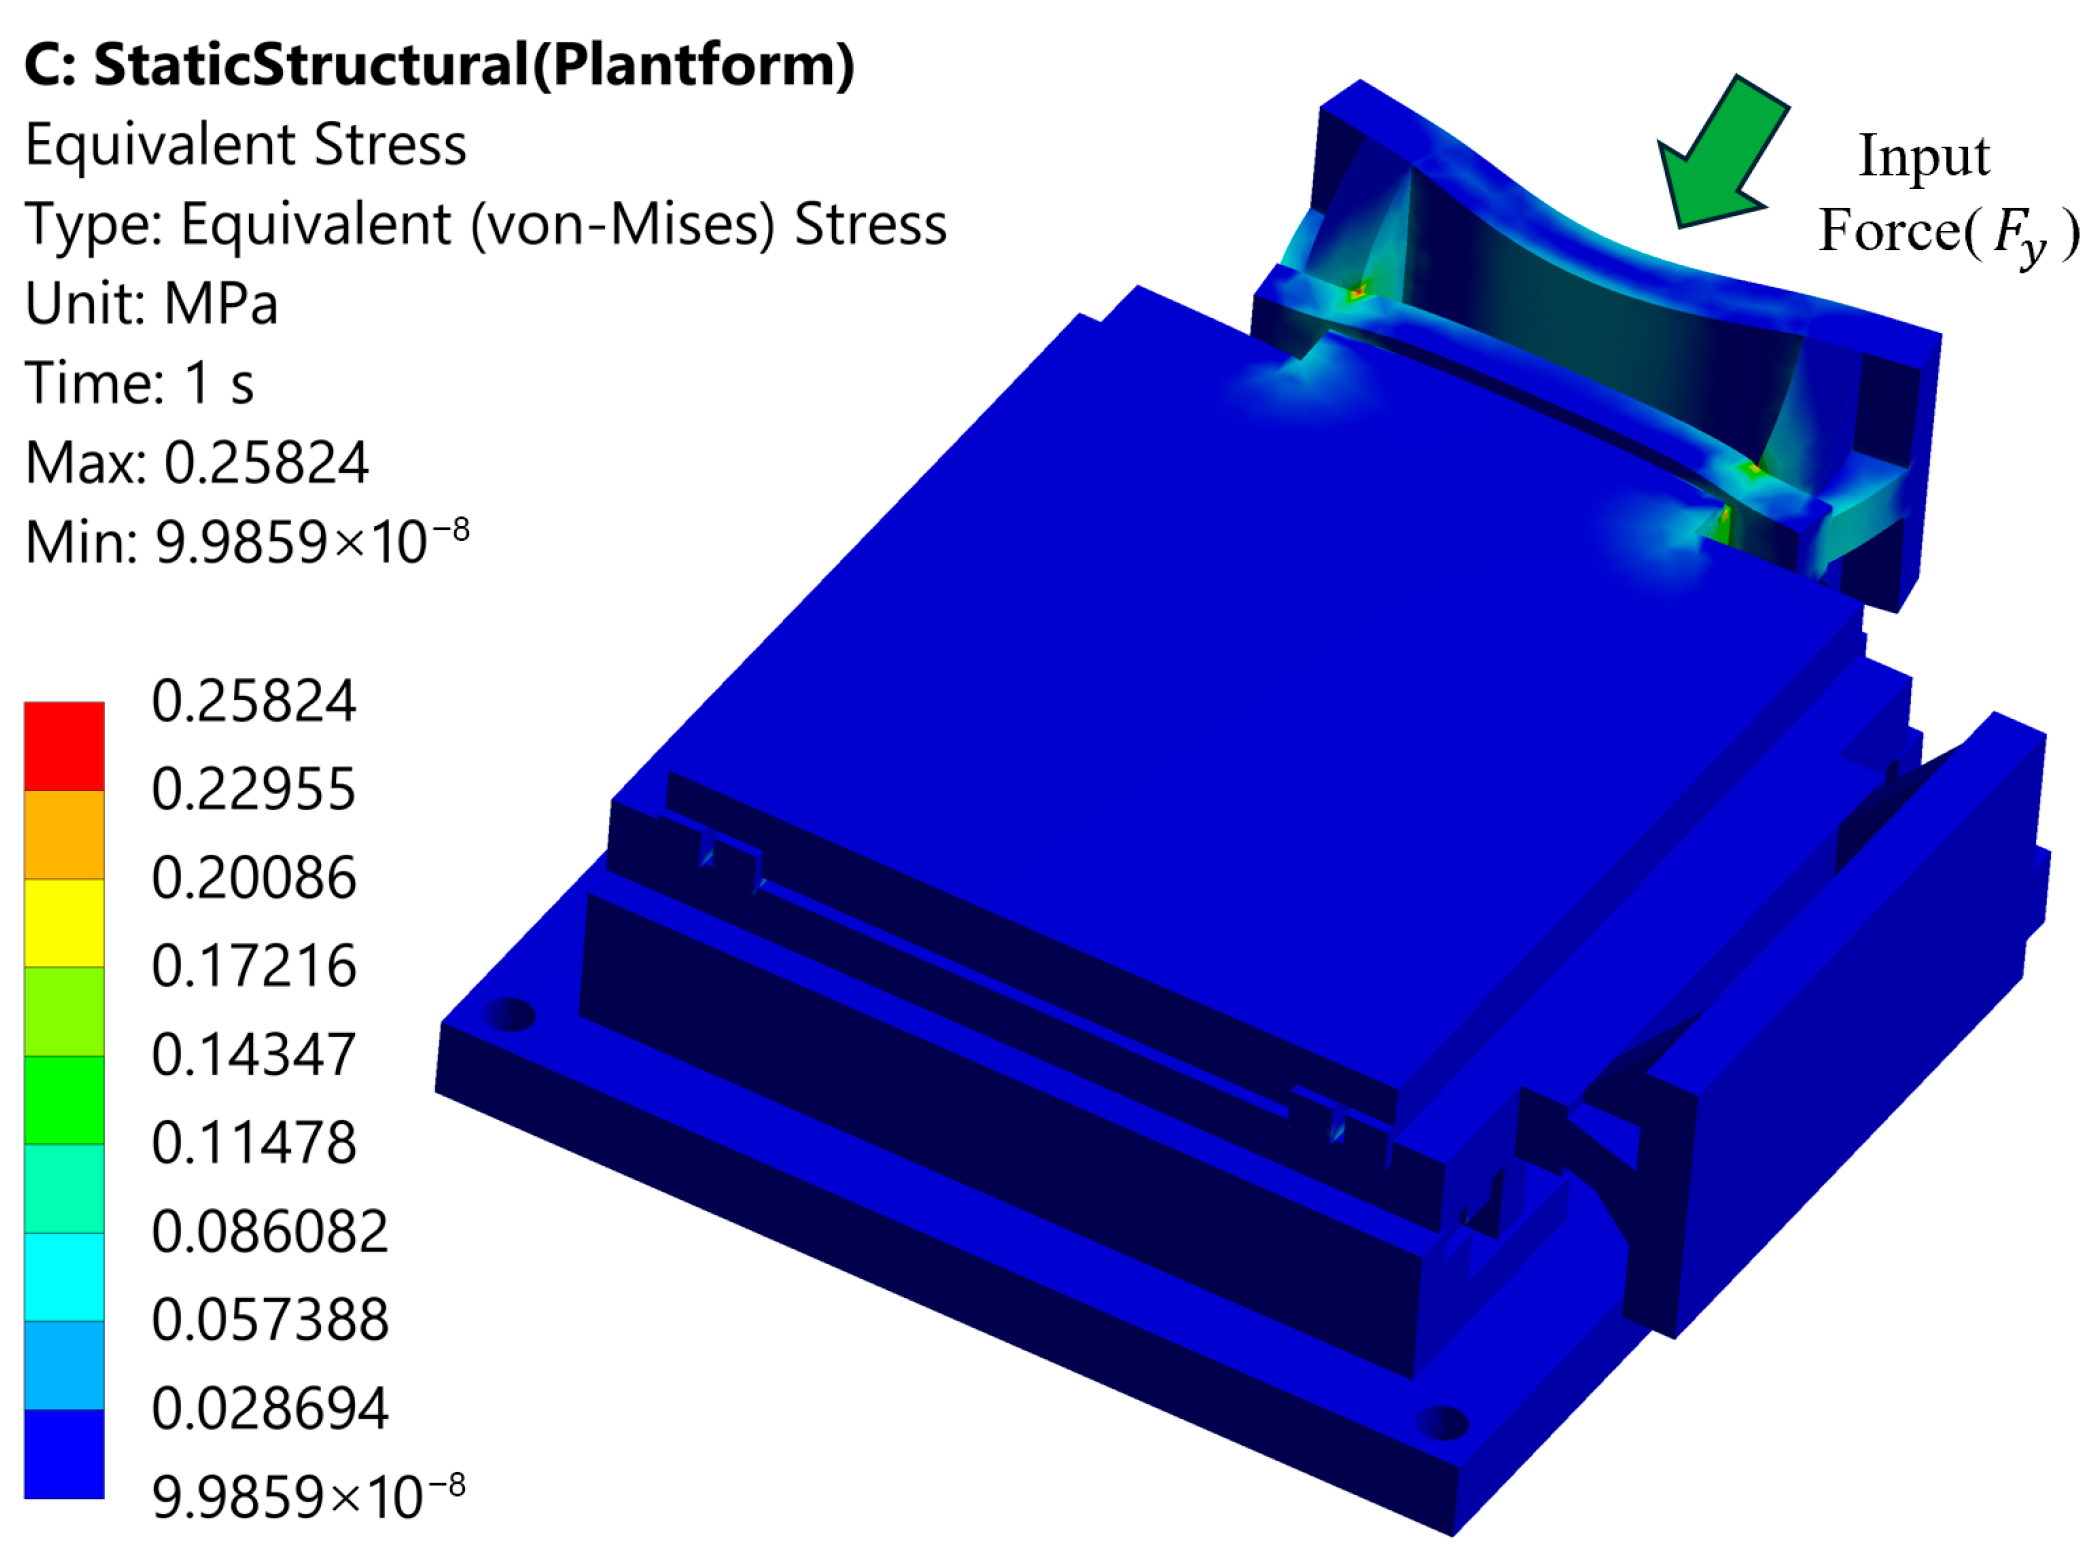
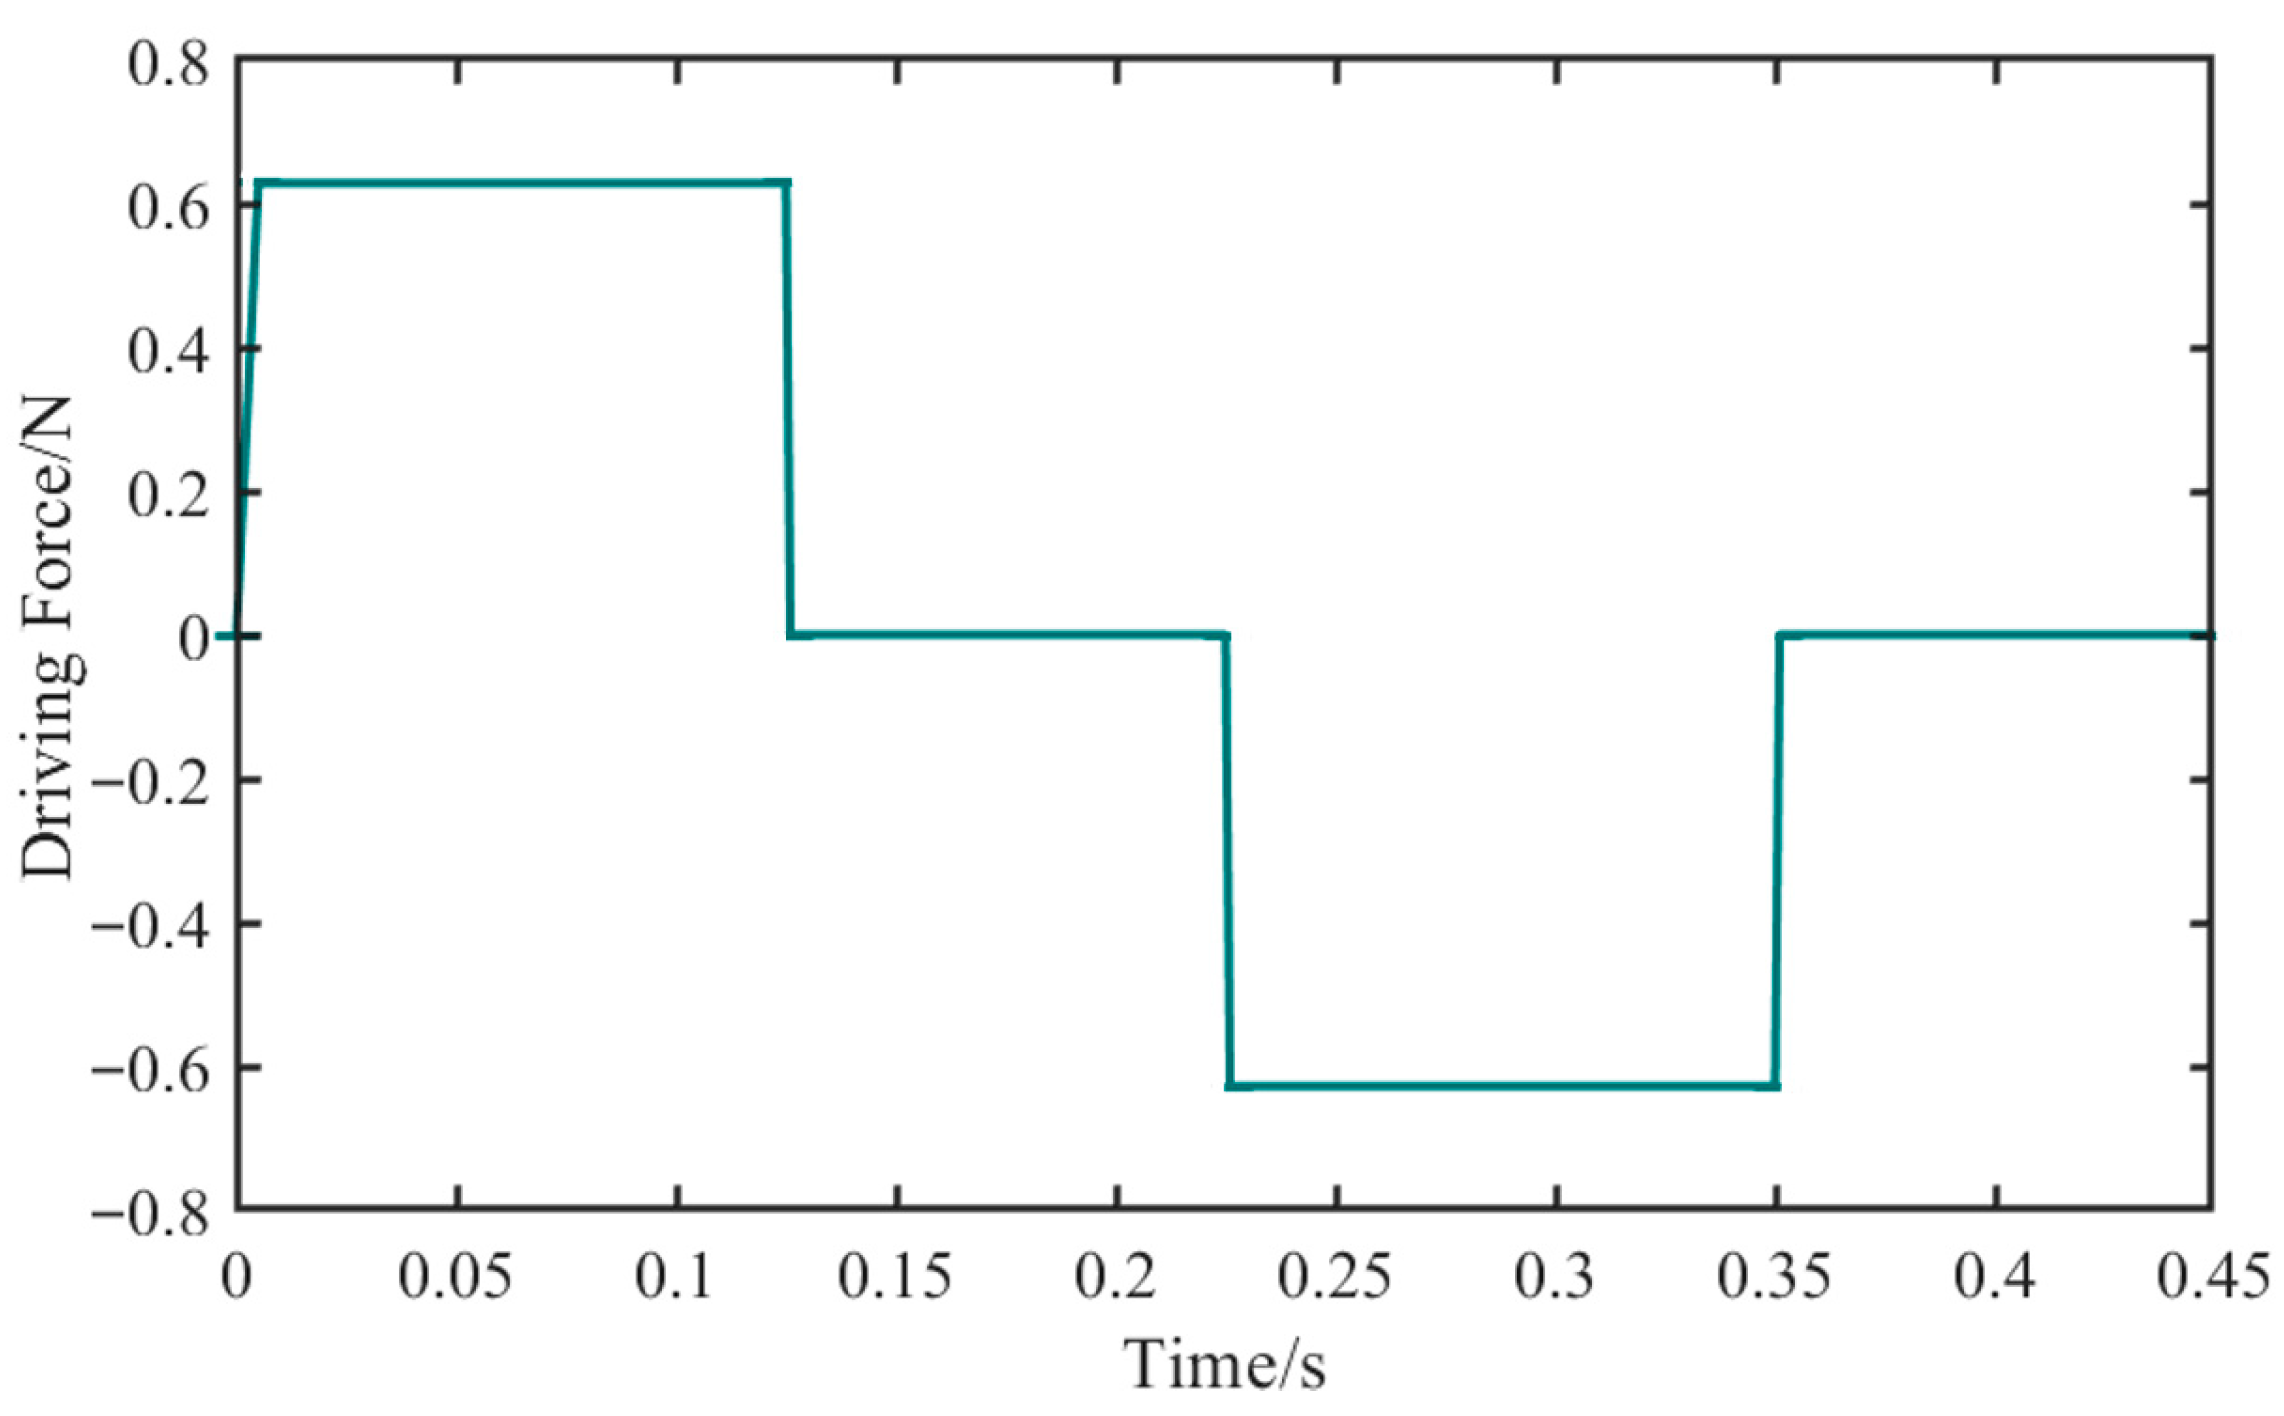
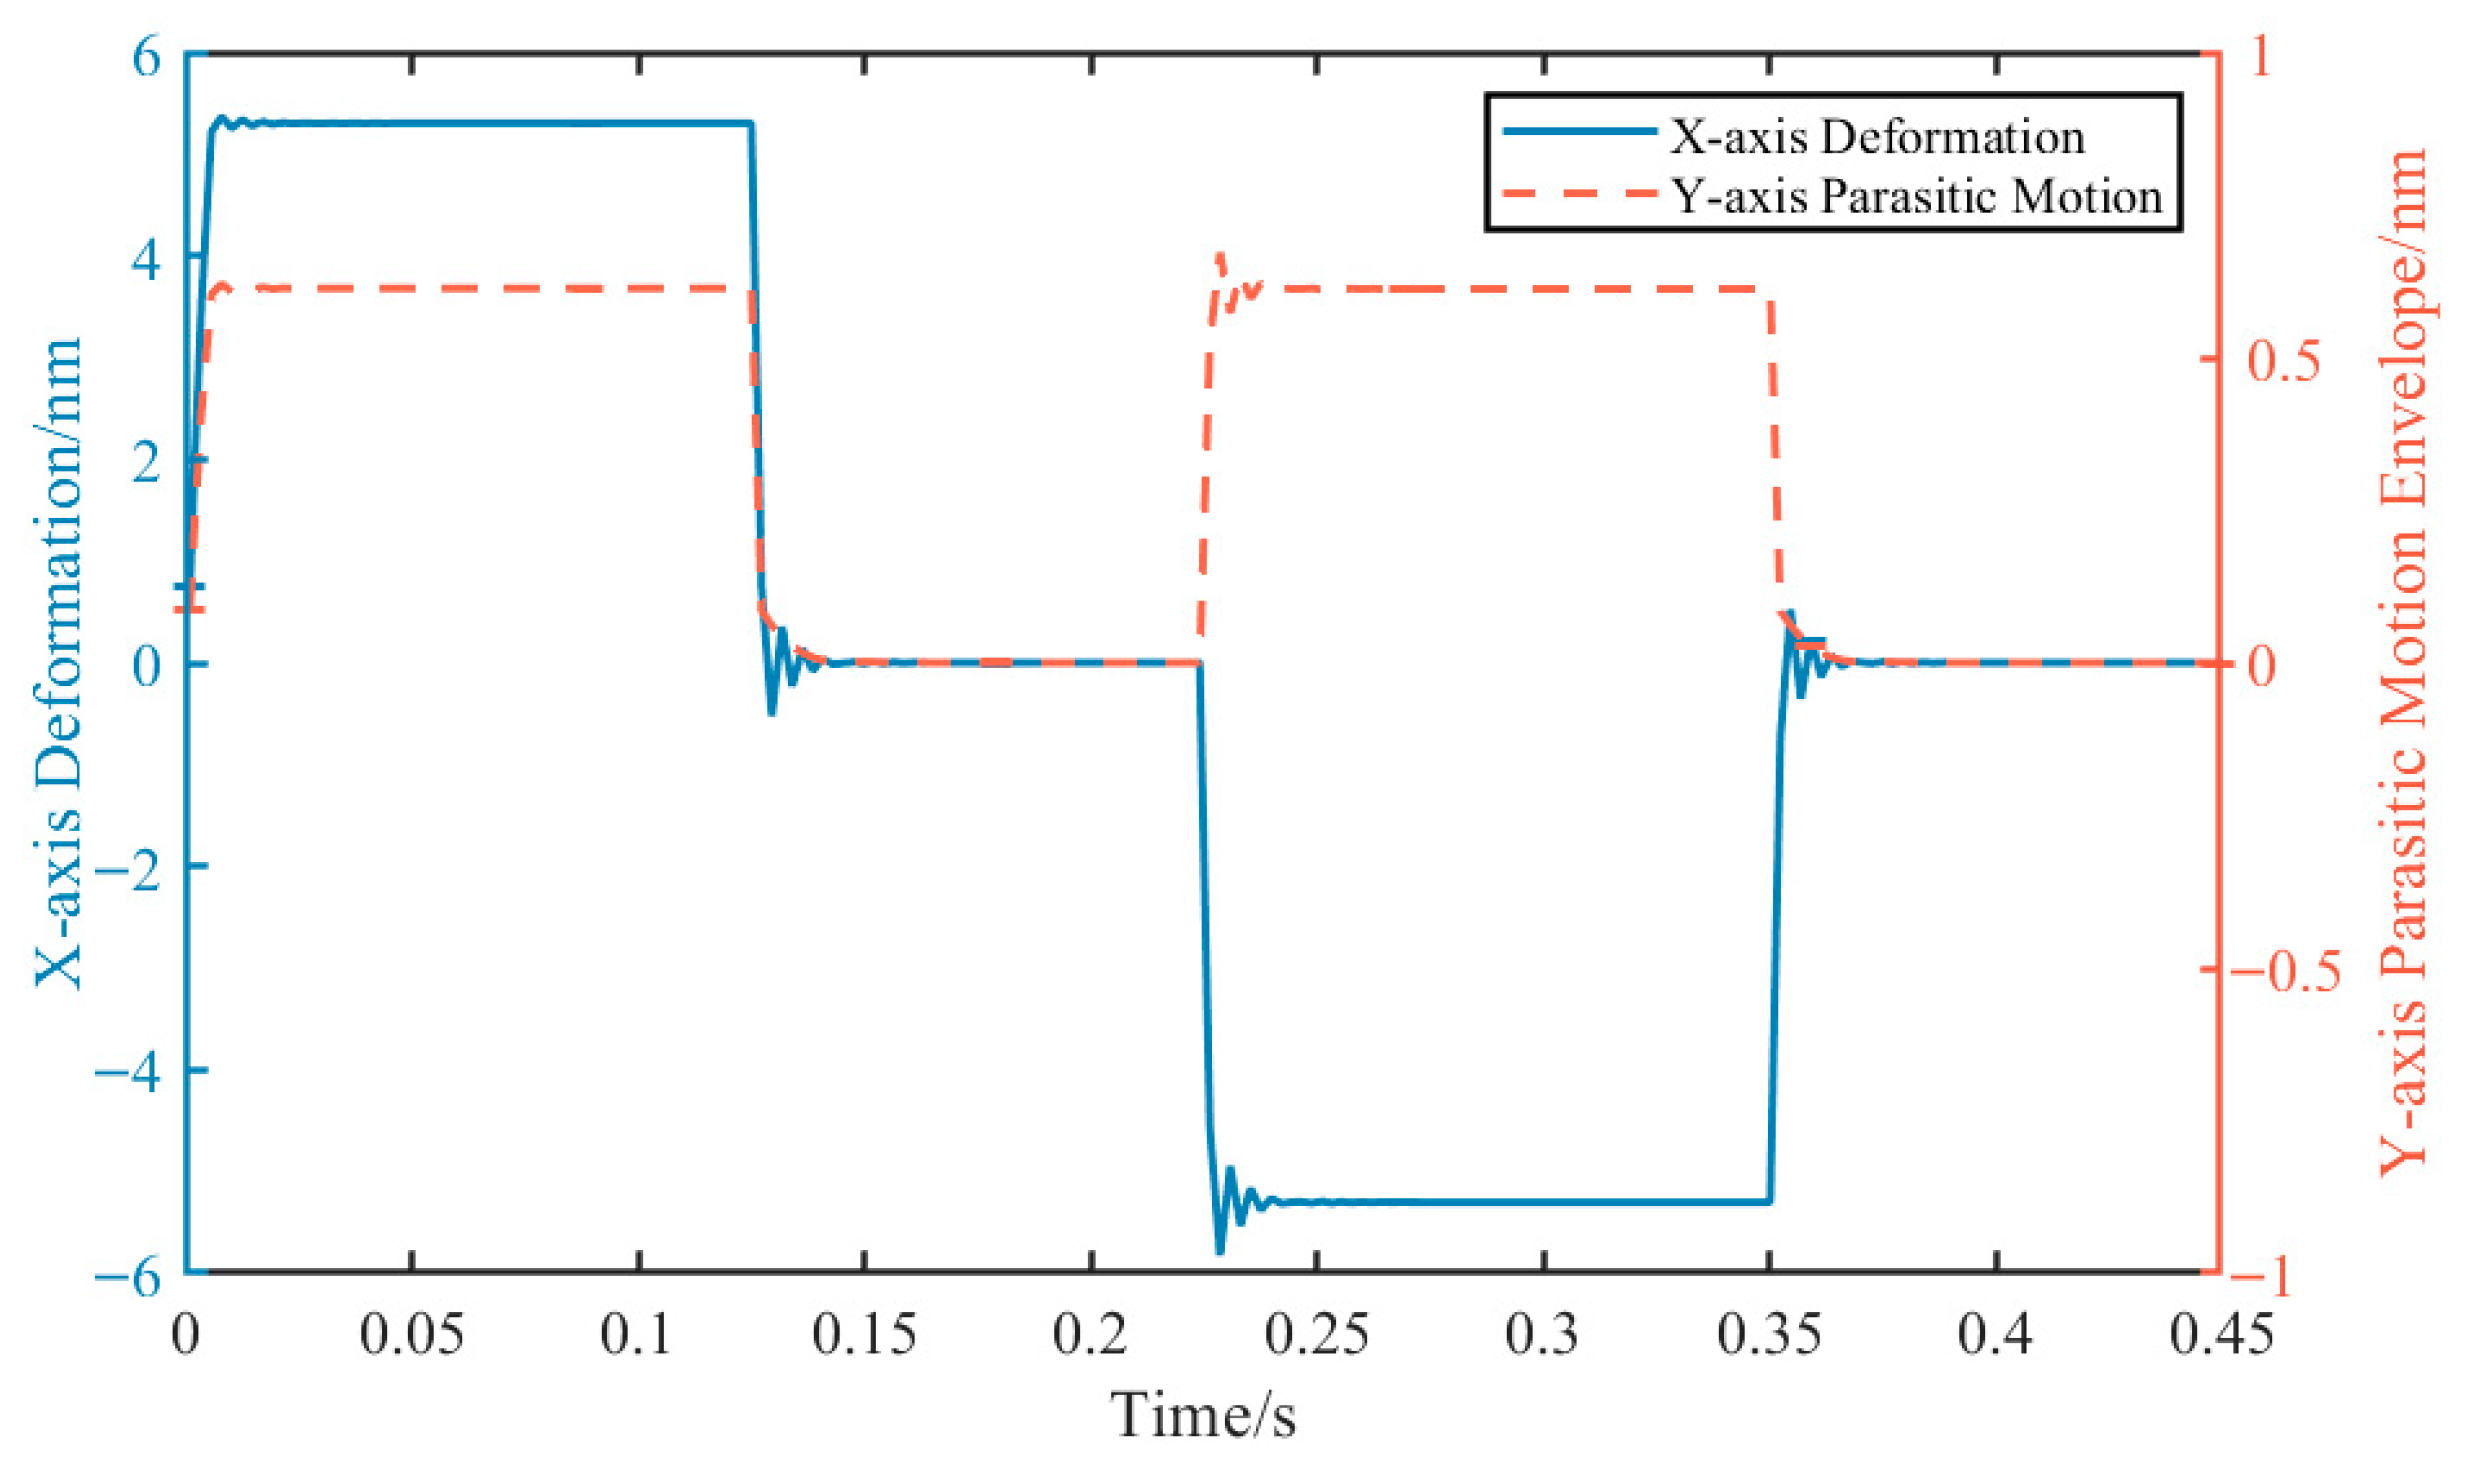
- Mechanical Reliability and Parasitic Motion Suppression: Static and transient analyses confirm that the structure possesses sufficient mechanical strength reserves. Furthermore, transient dynamic simulations indicate that the mechanism suppresses cross-axis parasitic displacement to a sub-nanometer level (0.61 nm) during high-acceleration maneuvers, providing initial evidence of the decoupling effectiveness of the integrated arm-rail design compared to certain rigid solutions.
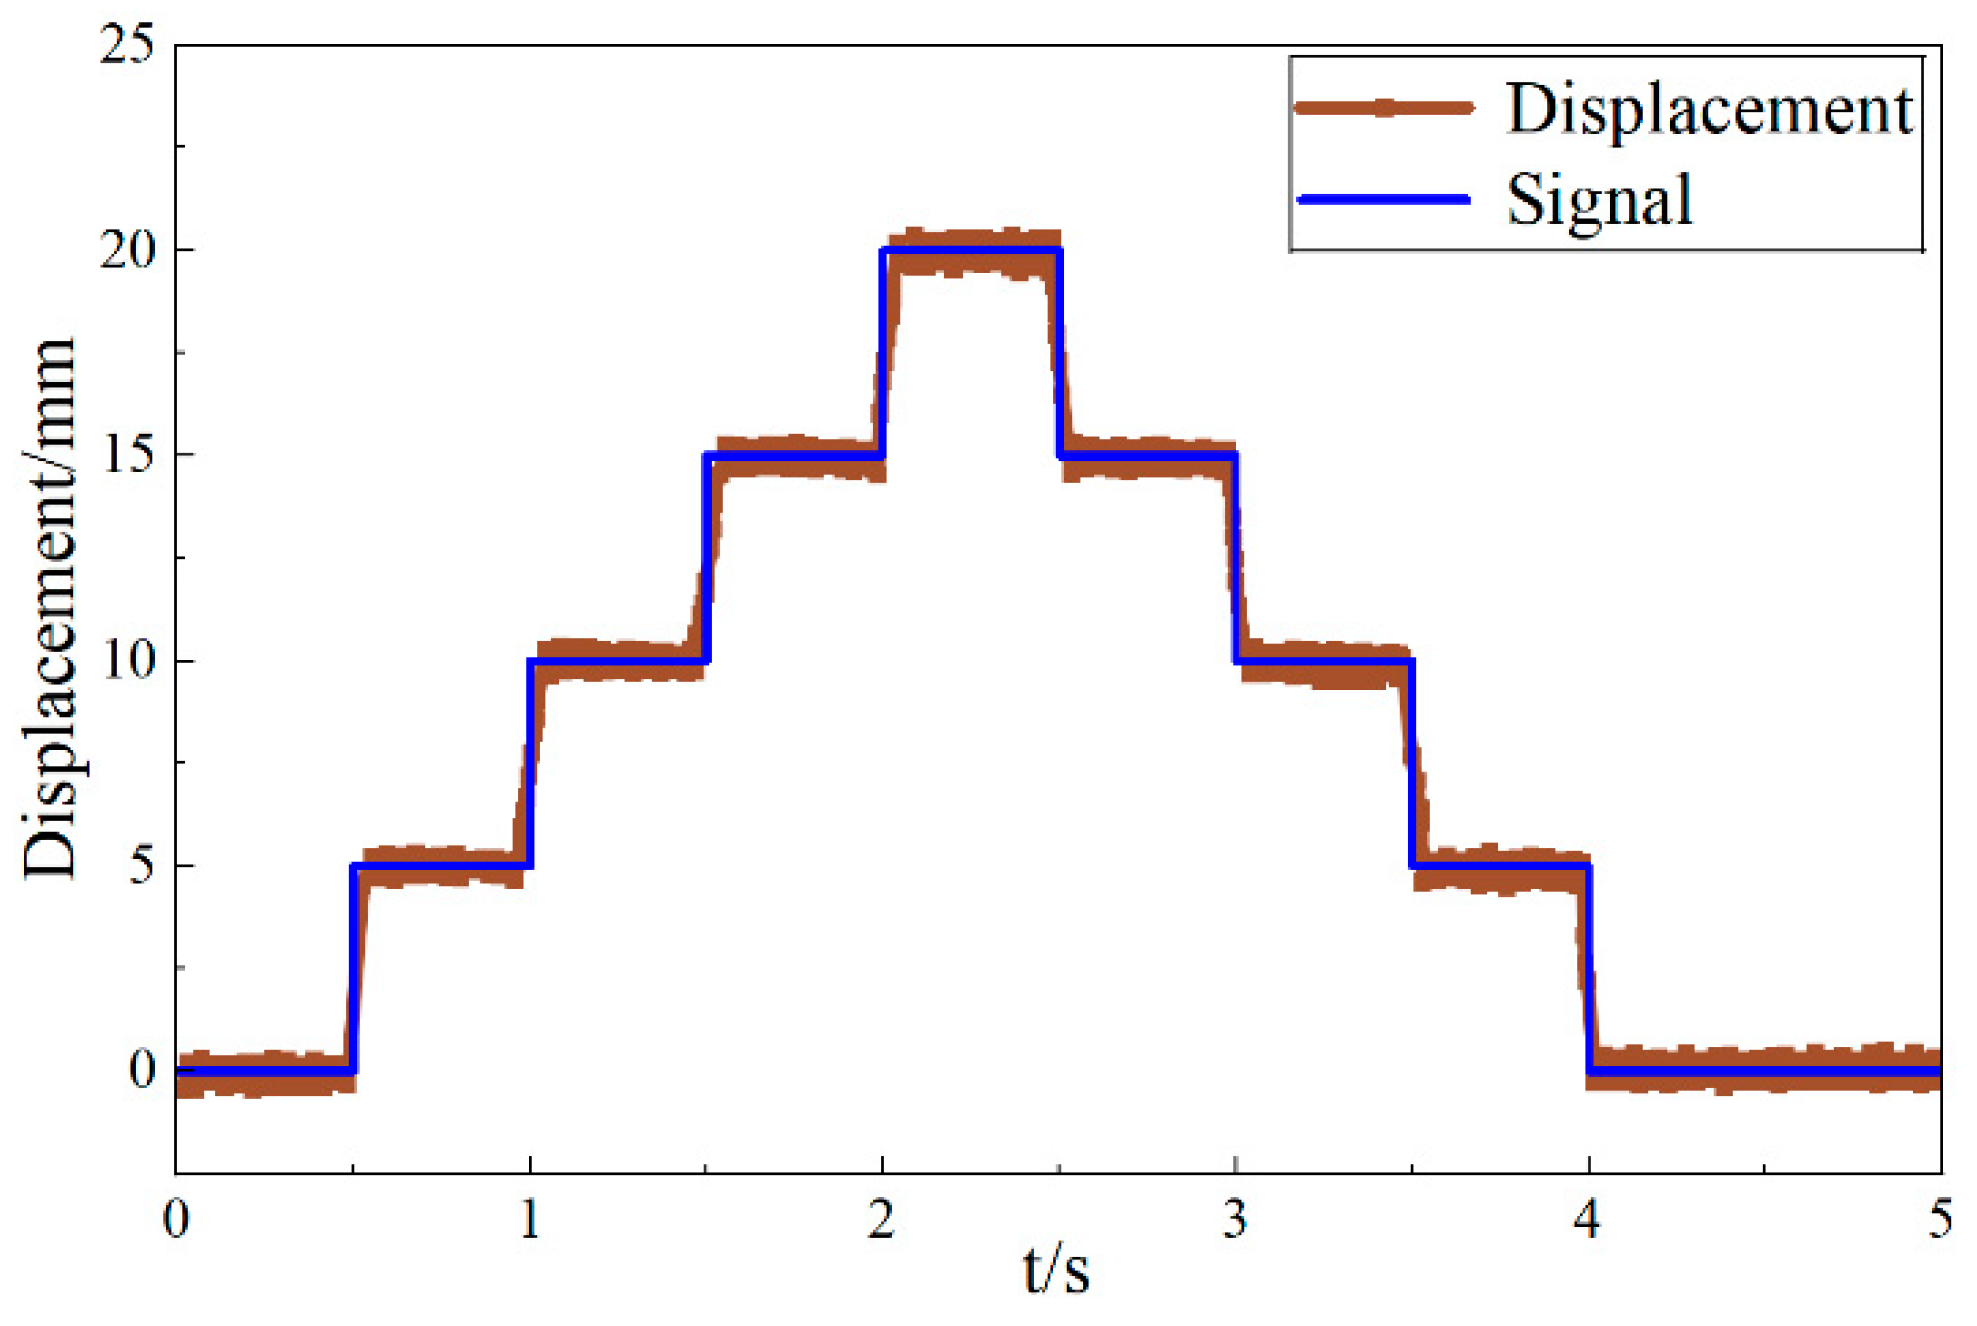
- Experimental Validation and Positioning Reliability: To enhance the evaluation, a preliminary analysis of measurement repeatability and uncertainty was incorporated. For a 5 mm step command, the positioning deviation is evaluated within an uncertainty band of 0.005 mm based on a 1.65σ confidence interval. These results suggest that the proposed platform offers a feasible alternative for high-performance precision positioning in terms of rigidity and stability.
Author Contributions
Funding
Data Availability Statement
Conflicts of Interest
Appendix A
Appendix A.1

| Parameter | Symbol | Value |
|---|---|---|
| Overall Size | L × W × H | 210.5 × 218.5 × 69 mm |
| Working Stroke | Seff | ±10 mm |
| Max Rail Stroke | Smax | ±40 mm |
| Guide Rail Length | Lrail | 150 mm |
| Upper Moving Mass | Mx | 1.57 kg |
| Lower Moving Mass | My | 2.14 kg |
Appendix A.2
| Parameter | Symbol | Value/Limit |
|---|---|---|
| Roller Diameter | Dω | 3 mm |
| Rail System Height | A | 18 mm |
| Basic Dynamic Load | Croller | 130 N |
| Max Acceleration | amax | 50 m/s2 |
| Max. Velocity | vmax | 1 m/s |
| Operating Temp. | Top | −40 to 80 °C |
| Material Hardness | HRC | 58–62 HRC |
Appendix A.3
References
- Li, X.; Zhang, L.; Jiang, B.; Fang, J.; Zheng, Y. Research Trends in China for Macro-Micro Motion Platform for Microelectronics Manufacturing Industry. J. Adv. Mech. Des. Syst. Manuf. 2021, 15, JAMDSM0032. [Google Scholar] [CrossRef] [Scilit]
- Liu, M.; Yu, Y.; Cui, L.; Ji, N.; Deng, X. Research on Micro-/Nano-Positioning System Driven by a Stepper Motor. Actuators 2024, 13, 246. [Google Scholar] [CrossRef] [Scilit]
- Yuan, L.; Wang, L.; Qi, R.; Li, Y.; Liu, C.; Luo, G. A 2-DOF Piezoelectric Platform for Cross-Scale Semiconductor Inspection. Int. J. Mech. Sci. 2024, 284, 109765. [Google Scholar] [CrossRef] [Scilit]
- Zhang, Y.; Hu, G.X.; Gong, J.; Wei, X.T. Key Technologies and Development of Micro-Nano Positioning Platform with Large Travel. Appl. Mech. Mater. 2011, 55–57, 929–932. [Google Scholar] [CrossRef] [Scilit]
- Li, J.; Zhao, H.; Qu, X.; Qu, H.; Zhou, X.; Fan, Z.; Ma, Z.; Fu, H. Development of a Compact 2-DOF Precision Piezoelectric Positioning Platform Based on Inchworm Principle. Sens. Actuators A Phys. 2015, 222, 87–95. [Google Scholar] [CrossRef] [Scilit]
- Yuan, L.; Wang, L.; Qi, R.; Zhao, Z.; Jin, J.; Zhao, C. A Novel Hollow-Type XY Piezoelectric Positioning Platform. Int. J. Mech. Sci. 2023, 255, 108496. [Google Scholar] [CrossRef] [Scilit]
- Gan, J.; Xie, W.; Yang, W.; Lei, S.; Lei, B. Design of a Novel Z-Shaped Flexure Hinge and a 2DOF XY Precision Positioning Platform. Precis. Eng. 2025, 93, 459–469. [Google Scholar] [CrossRef] [Scilit]
- Dong, G.; Sun, S.; Kong, X.; Chen, X.; Yin, T.; Wu, N.; Huang, P.; Wang, Z. Design and Analysis of a New Micro-Positioning Platform for Ceramic Material Testing. Microsyst. Technol. 2024, 30, 55–64. [Google Scholar] [CrossRef] [Scilit]
- Li, C.; Kang, S. Preliminary Design and Simulation Analysis of a Novel Large-Stroke 3-DOF Parallel Micro-Positioning Platform. Machines 2025, 13, 404. [Google Scholar] [CrossRef] [Scilit]
- Tian, Y.; Liu, C.; Liu, X.; Wang, F.; Li, X.; Qin, Y.; Zhang, D.; Shirinzadeh, B. Design, Modelling and Characterization of a 2-DOF Precision Positioning Platform. Trans. Inst. Meas. Control 2015, 37, 396–405. [Google Scholar] [CrossRef] [Scilit]
- Huang, H.; Zhao, H.; Fan, Z.; Zhang, H.; Ma, Z.; Yang, Z. Analysis and Experiments of a Novel and Compact 3-DOF Precision Positioning Platform. J. Mech. Sci. Technol. 2013, 27, 3347–3356. [Google Scholar] [CrossRef] [Scilit]
- Wang, G.; Wang, Y.; Lv, B.; Ma, R.; Liu, L. Research on a New Type of Rigid-Flexible Coupling 3-DOF Micro-Positioning Platform. Micromachines 2020, 11, 1015. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Sun, F.; Hao, Y.; Xu, F.; Jin, J.; Li, Q.; Tong, L.; Zhang, M.; Zhang, X. Proposal of an Equal-Stiffness and Equal-Stroke 2D Micro-Positioning Platform Driven by Piezoelectric Actuators. Actuators 2020, 9, 47. [Google Scholar] [CrossRef] [Scilit]
- Zhang, L.; Yan, H.; Sun, H.; Hu, M. Multi-Objective Optimization of Flexible Positioning Platform Considering Displacement Frequency and Dynamic Stiffness Responses. Sci. Rep. 2025, 15, 8904. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Yang, Z.; Li, X.; Tang, J.; Huang, H.; Zhao, H.; Cheng, Y.; Liu, S.; Li, C.; Xiong, M. A Bionic Stick–Slip Piezo-Driven Positioning Platform Designed by Imitating the Structure and Movement of the Crab. J. Bionic Eng. 2023, 20, 2590–2600. [Google Scholar]
- Wang, L.; Song, Z.; Chen, B.; Wu, H. Precision Tracking of an XY Micro-Positioning Stage Using a Generalized Asymmetric Bouc-Wen Model and Error-Based ADRC. Sens. Actuators A Phys. 2025, 396, 117191. [Google Scholar]
- Wang, L.; Chen, B.; Chang, T.; Yao, J.; Wu, H.; Ding, S. Design and Control of a Novel XY Compliant Micro-Positioning Stage with Low Geometric Nonlinearity and Large Workspace. Mechatronics 2026, 114, 103437. [Google Scholar] [CrossRef] [Scilit]
- Zhang, W.; Zhang, H.; Mu, J.; Wang, S. Design of a Single-Sided, Coreless, Flat-Type Linear Voice Coil Motor. Actuators 2023, 12, 77. [Google Scholar] [CrossRef] [Scilit]
- Kang, S.; Jeong, Y.-G.; Choi, Y.-M. Design of a Finger-Sized Voice Coil Motor for High-Speed Scanners. Int. J. Precis. Eng. Manuf. 2023, 24, 209–217. [Google Scholar] [CrossRef] [Scilit]
- Kim, J.-Y.; Ahn, D. Analysis of High Force Voice Coil Motors for Magnetic Levitation. Actuators 2020, 9, 133. [Google Scholar] [CrossRef] [Scilit]
- Ahn, D.H.; Hong, D.P.; Gweon, D.G. Design of a High Force Voice Coil Motor. Appl. Mech. Mater. 2013, 483, 559–562. [Google Scholar] [CrossRef] [Scilit]
- Lin, R.; Li, Y.; Zhang, Y.; Wang, T.; Wang, Z.; Song, Z.; Dou, Z.; Qian, J. Design of A Flexure-Based Mixed-Kinematic XY High-Precision Positioning Platform with Large Range. Mech. Mach. Theory 2019, 142, 103609. [Google Scholar] [CrossRef] [Scilit]
- Liu, C.; Liu, W.; Wang, S.; Li, T. Structural Design and Damping Characteristics Analysis of Voice Coil Motor Actuator for Air Floating Isolation Platform. J. Phys. Conf. Ser. 2025, 3126, 012007. [Google Scholar] [CrossRef] [Scilit]
- Jeong, J.H.; Kim, M.H.; Woo, S.W.; Gweon, D.G.; Hong, D.P. Optimal Design of Voice Coil Motor for Micro Stage. Appl. Mech. Mater. 2014, 607, 507–510. [Google Scholar] [CrossRef] [Scilit]
- Feng, X.M.; Li, S.; Li, H.X.; Zhang, D.W. Voice Coil Actuator Characteristics Study. Small Spec. Electr. Mach. 2014, 42, 38–40. [Google Scholar]
- Zhang, Q.; Zhao, J.; Peng, Y.; Pu, H.; Yang, Y. A Novel Amplification Ratio Model of a Decoupled XY Precision Positioning Stage Combined with Elastic Beam Theory and Castigliano’s Second Theorem Considering the Exact Loading Force. Mech. Syst. Signal Process. 2020, 136, 106473. [Google Scholar] [CrossRef] [Scilit]









| Parameter | Value |
|---|---|
| Force constant (N/Arms) | 12.3 |
| Stroke (mm) | 35 |
| Phase Inductance (mH) | 1.2 |
| Mover Weight (g) | 400 |
| Stator Weight (g) | 1750 |
| Peak Thrust (N) | 331 |
| Comparison Item | Motor Mover Decoupling | Connecting Arm with Rail Decoupling |
|---|---|---|
| Material Used in Simulation | Carbon Fiber Composite | 6061 Aluminum Alloy |
| First-Order Modal Frequency (Hz) | 564.97 | 1014 |
| Structural Stiffness | Relatively Low | High |
| Decoupling Structure | Suspended Mover | Integrated Arm |
| Material | Density (kg/m3) | Young’s Modulus (GPa) | Poisson’s Ratio |
|---|---|---|---|
| 6061 | 2750 | 68.9 | 0.33 |
| GCr15 | 7800 | 209 | 0.3 |
| Order | 1st | 2nd | 3rd | 4th | 5th | 6th |
|---|---|---|---|---|---|---|
| Frequency (Hz) | 864.82 | 1745.7 | 1981.9 | 2289 | 3258.4 | 3532 |
| Responses | Initial Design (From DOE) | Optimized Design | Improvement |
|---|---|---|---|
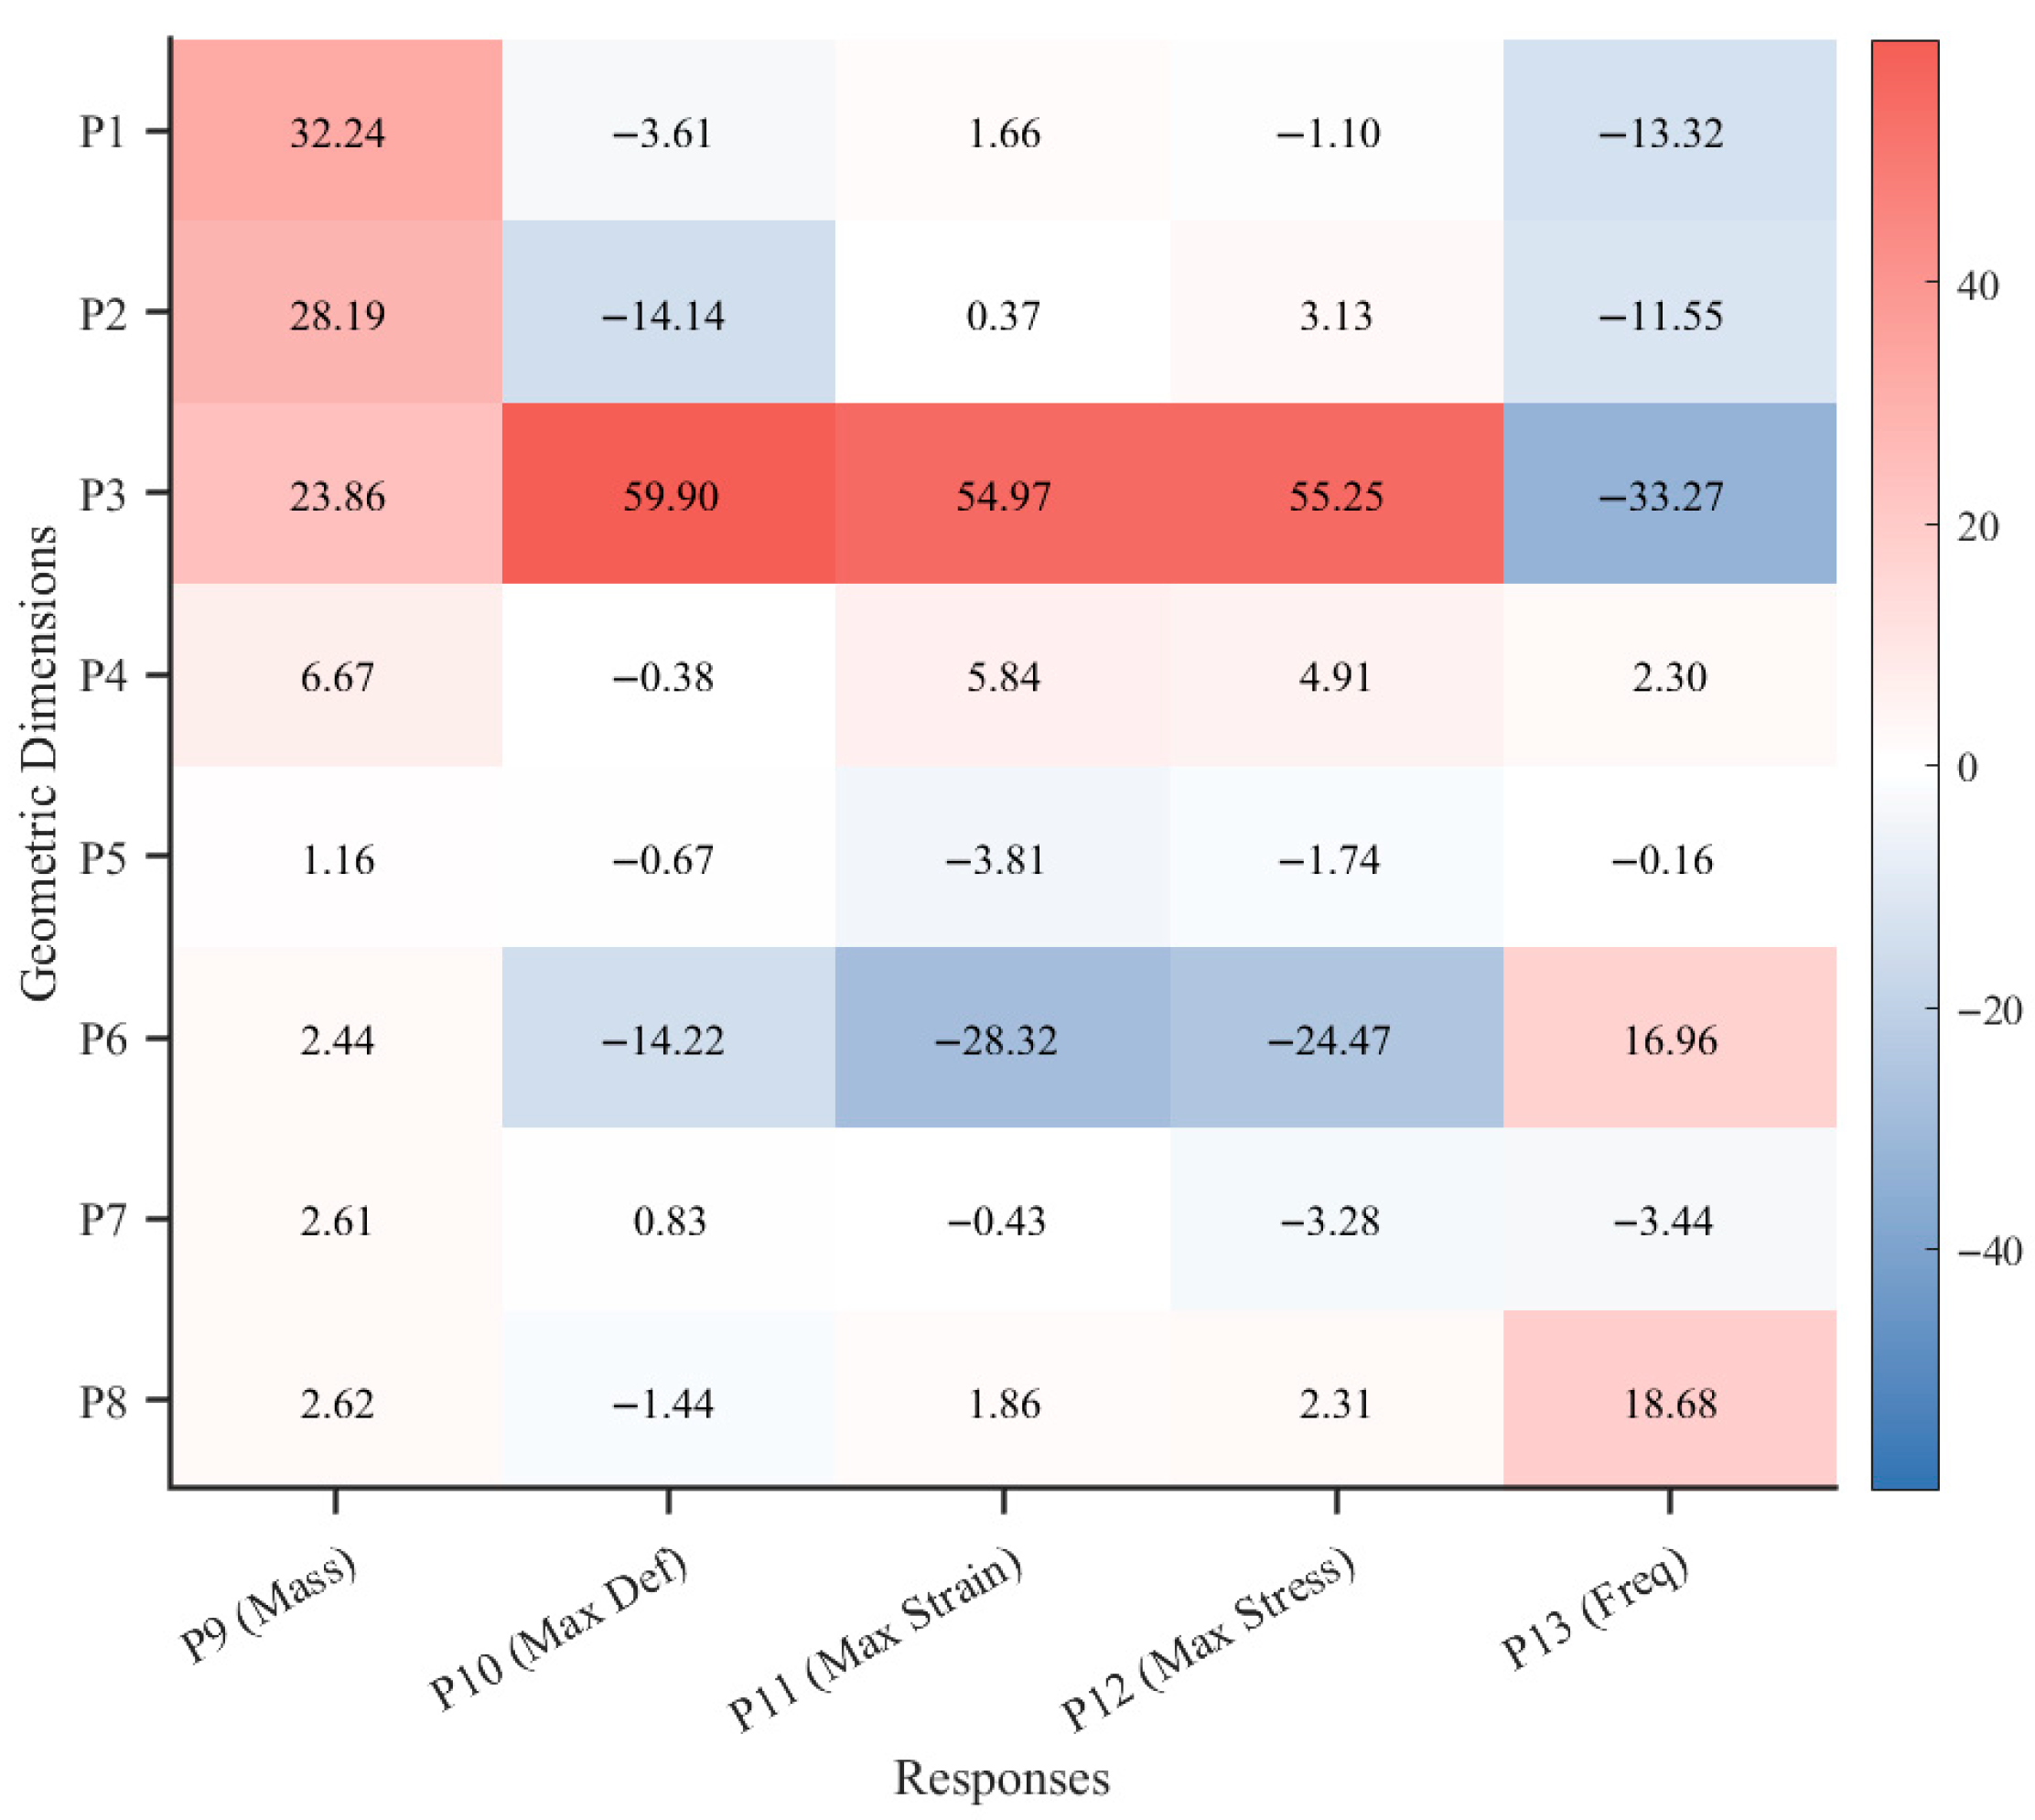
| Mass (P9) | 0.248 kg | 0.213 kg | 14.1% |
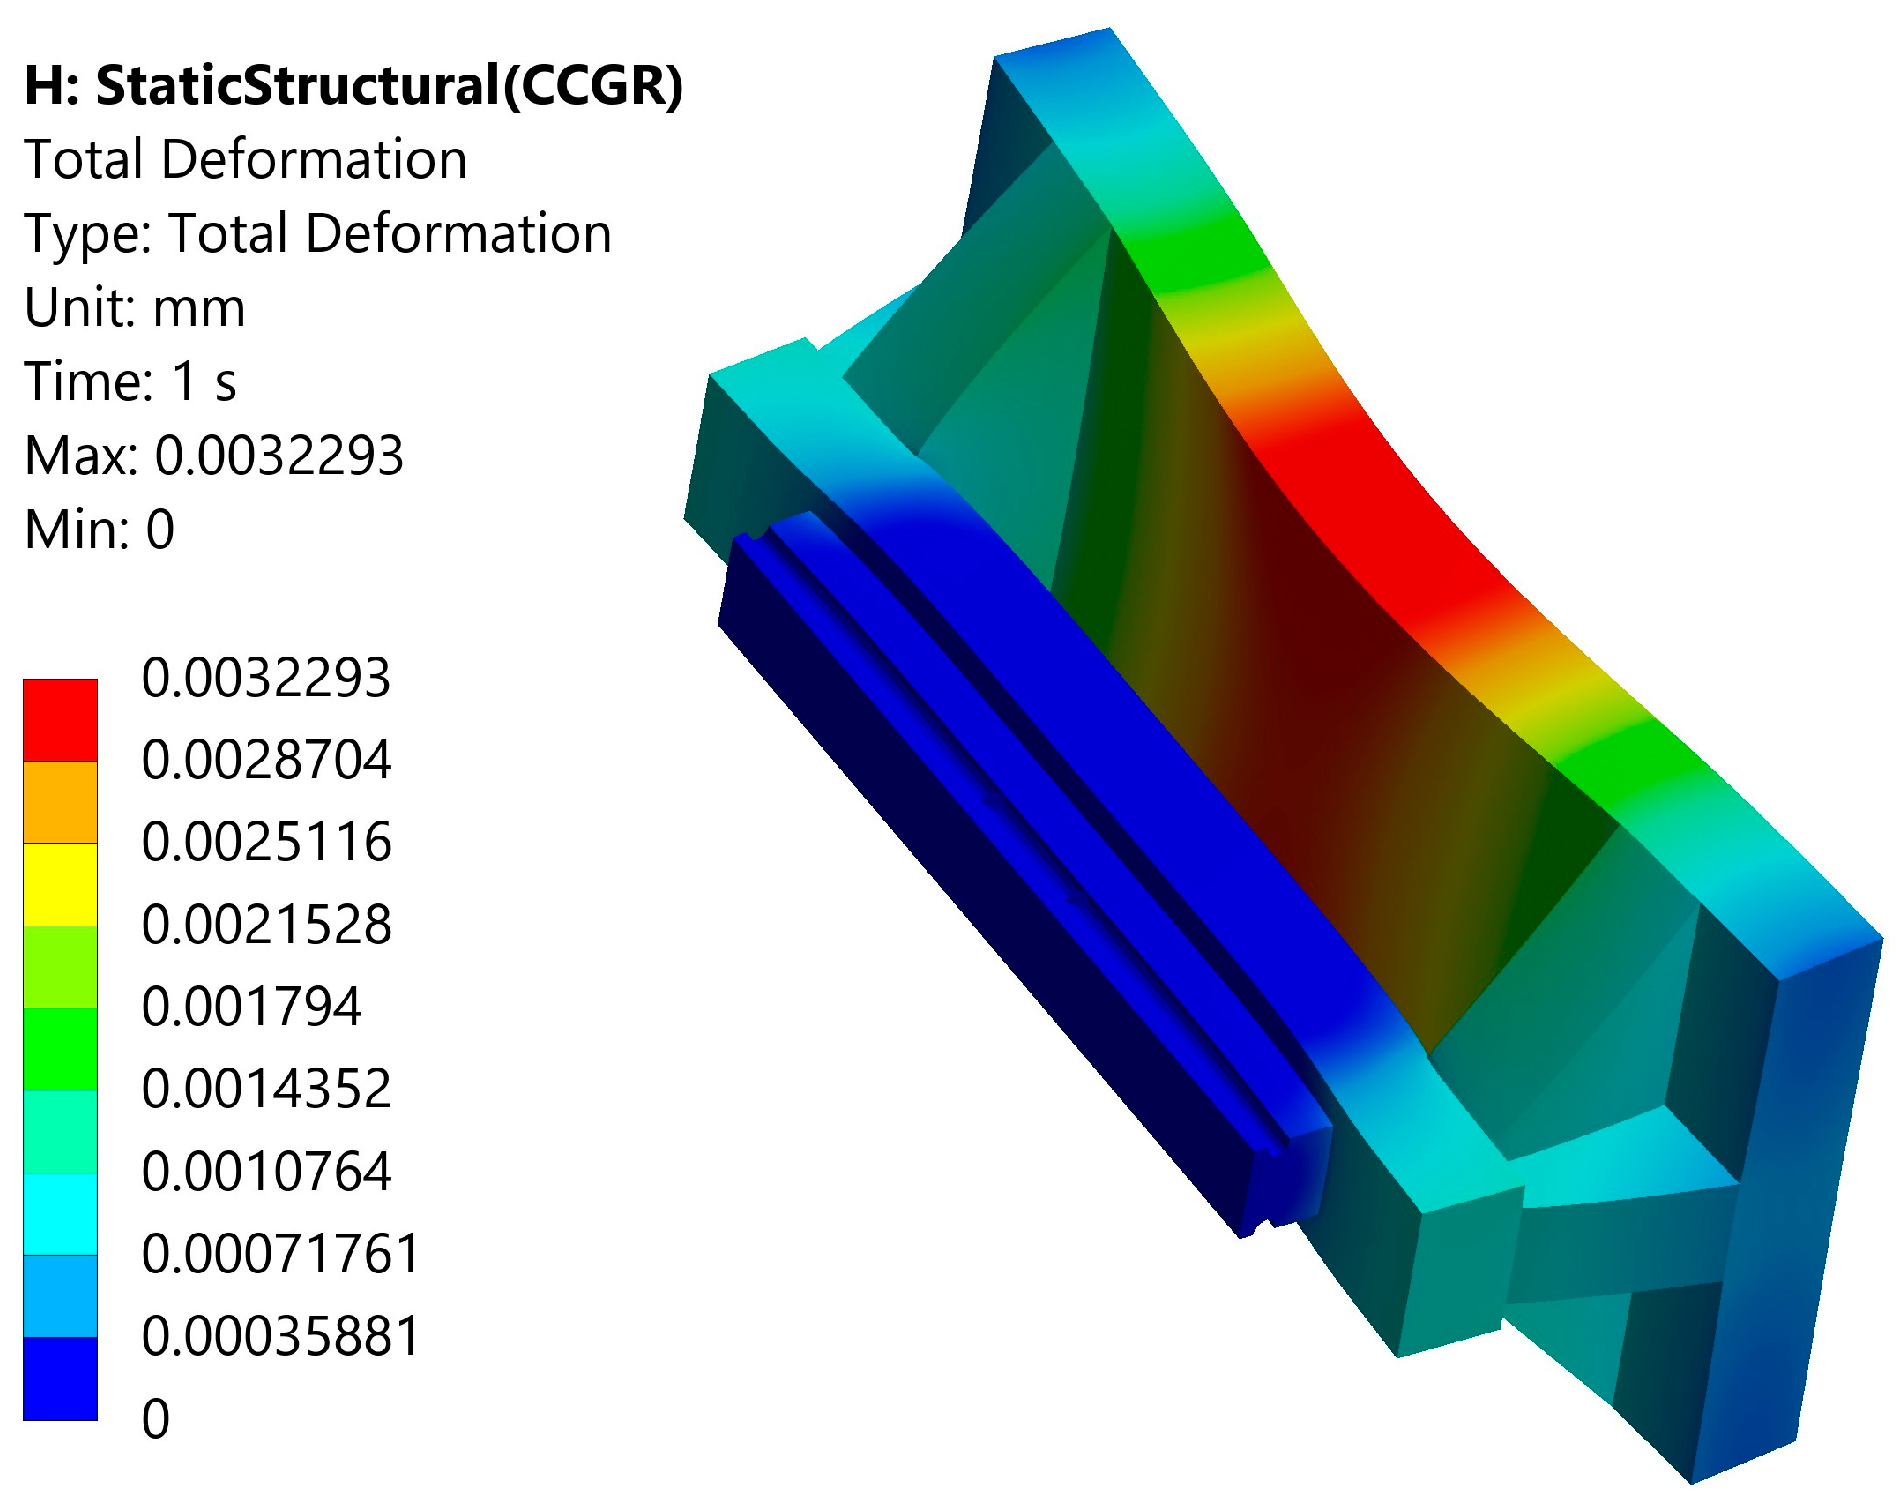
| Max Deformation (P10) | 3.21 × 10⁻³ mm | 1.88 × 10⁻³ mm | 41.4% |
| Max Equivalent Elastic Strain (P11) | 1.33 × 10⁻⁴ mm | 4.56 × 10⁻⁵ mm | 65.6% |
| Max Equivalent Stress (P12) | 8.43 MPa | 2.65 MPa | 68.5% |
| 1st Natural Frequency (P13) | 1006.26 Hz | 1522.66 Hz | 51.3% |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Jiang, J.; Fang, Y.; Feng, X.; Zhang, J.; Cui, H.; Lu, L.; Zhao, Z.; Xiao, Z. Design and Performance Analysis of an XY Precision Motion Platform with Decoupling Based on Connecting Arm and Guide Rail Integration. Machines 2026, 14, 340. https://doi.org/10.3390/machines14030340
Jiang J, Fang Y, Feng X, Zhang J, Cui H, Lu L, Zhao Z, Xiao Z. Design and Performance Analysis of an XY Precision Motion Platform with Decoupling Based on Connecting Arm and Guide Rail Integration. Machines. 2026; 14(3):340. https://doi.org/10.3390/machines14030340
Chicago/Turabian StyleJiang, Junjie, Yi Fang, Xulichen Feng, Jiahao Zhang, Hongyang Cui, Liangkun Lu, Zirui Zhao, and Zhiling Xiao. 2026. "Design and Performance Analysis of an XY Precision Motion Platform with Decoupling Based on Connecting Arm and Guide Rail Integration" Machines 14, no. 3: 340. https://doi.org/10.3390/machines14030340
APA StyleJiang, J., Fang, Y., Feng, X., Zhang, J., Cui, H., Lu, L., Zhao, Z., & Xiao, Z. (2026). Design and Performance Analysis of an XY Precision Motion Platform with Decoupling Based on Connecting Arm and Guide Rail Integration. Machines, 14(3), 340. https://doi.org/10.3390/machines14030340