Integrated Dynamic Modeling and Improved Deviation Coupling Control for Synchronous Motion of Multi-Joint Hydraulic Robotic Arms


Abstract
1. Introduction
2. Dynamic Modeling of Multi-Joint Robotic Manipulators
2.1. Mechanical Dynamic Modeling for Multi-Joint Robotic Manipulators
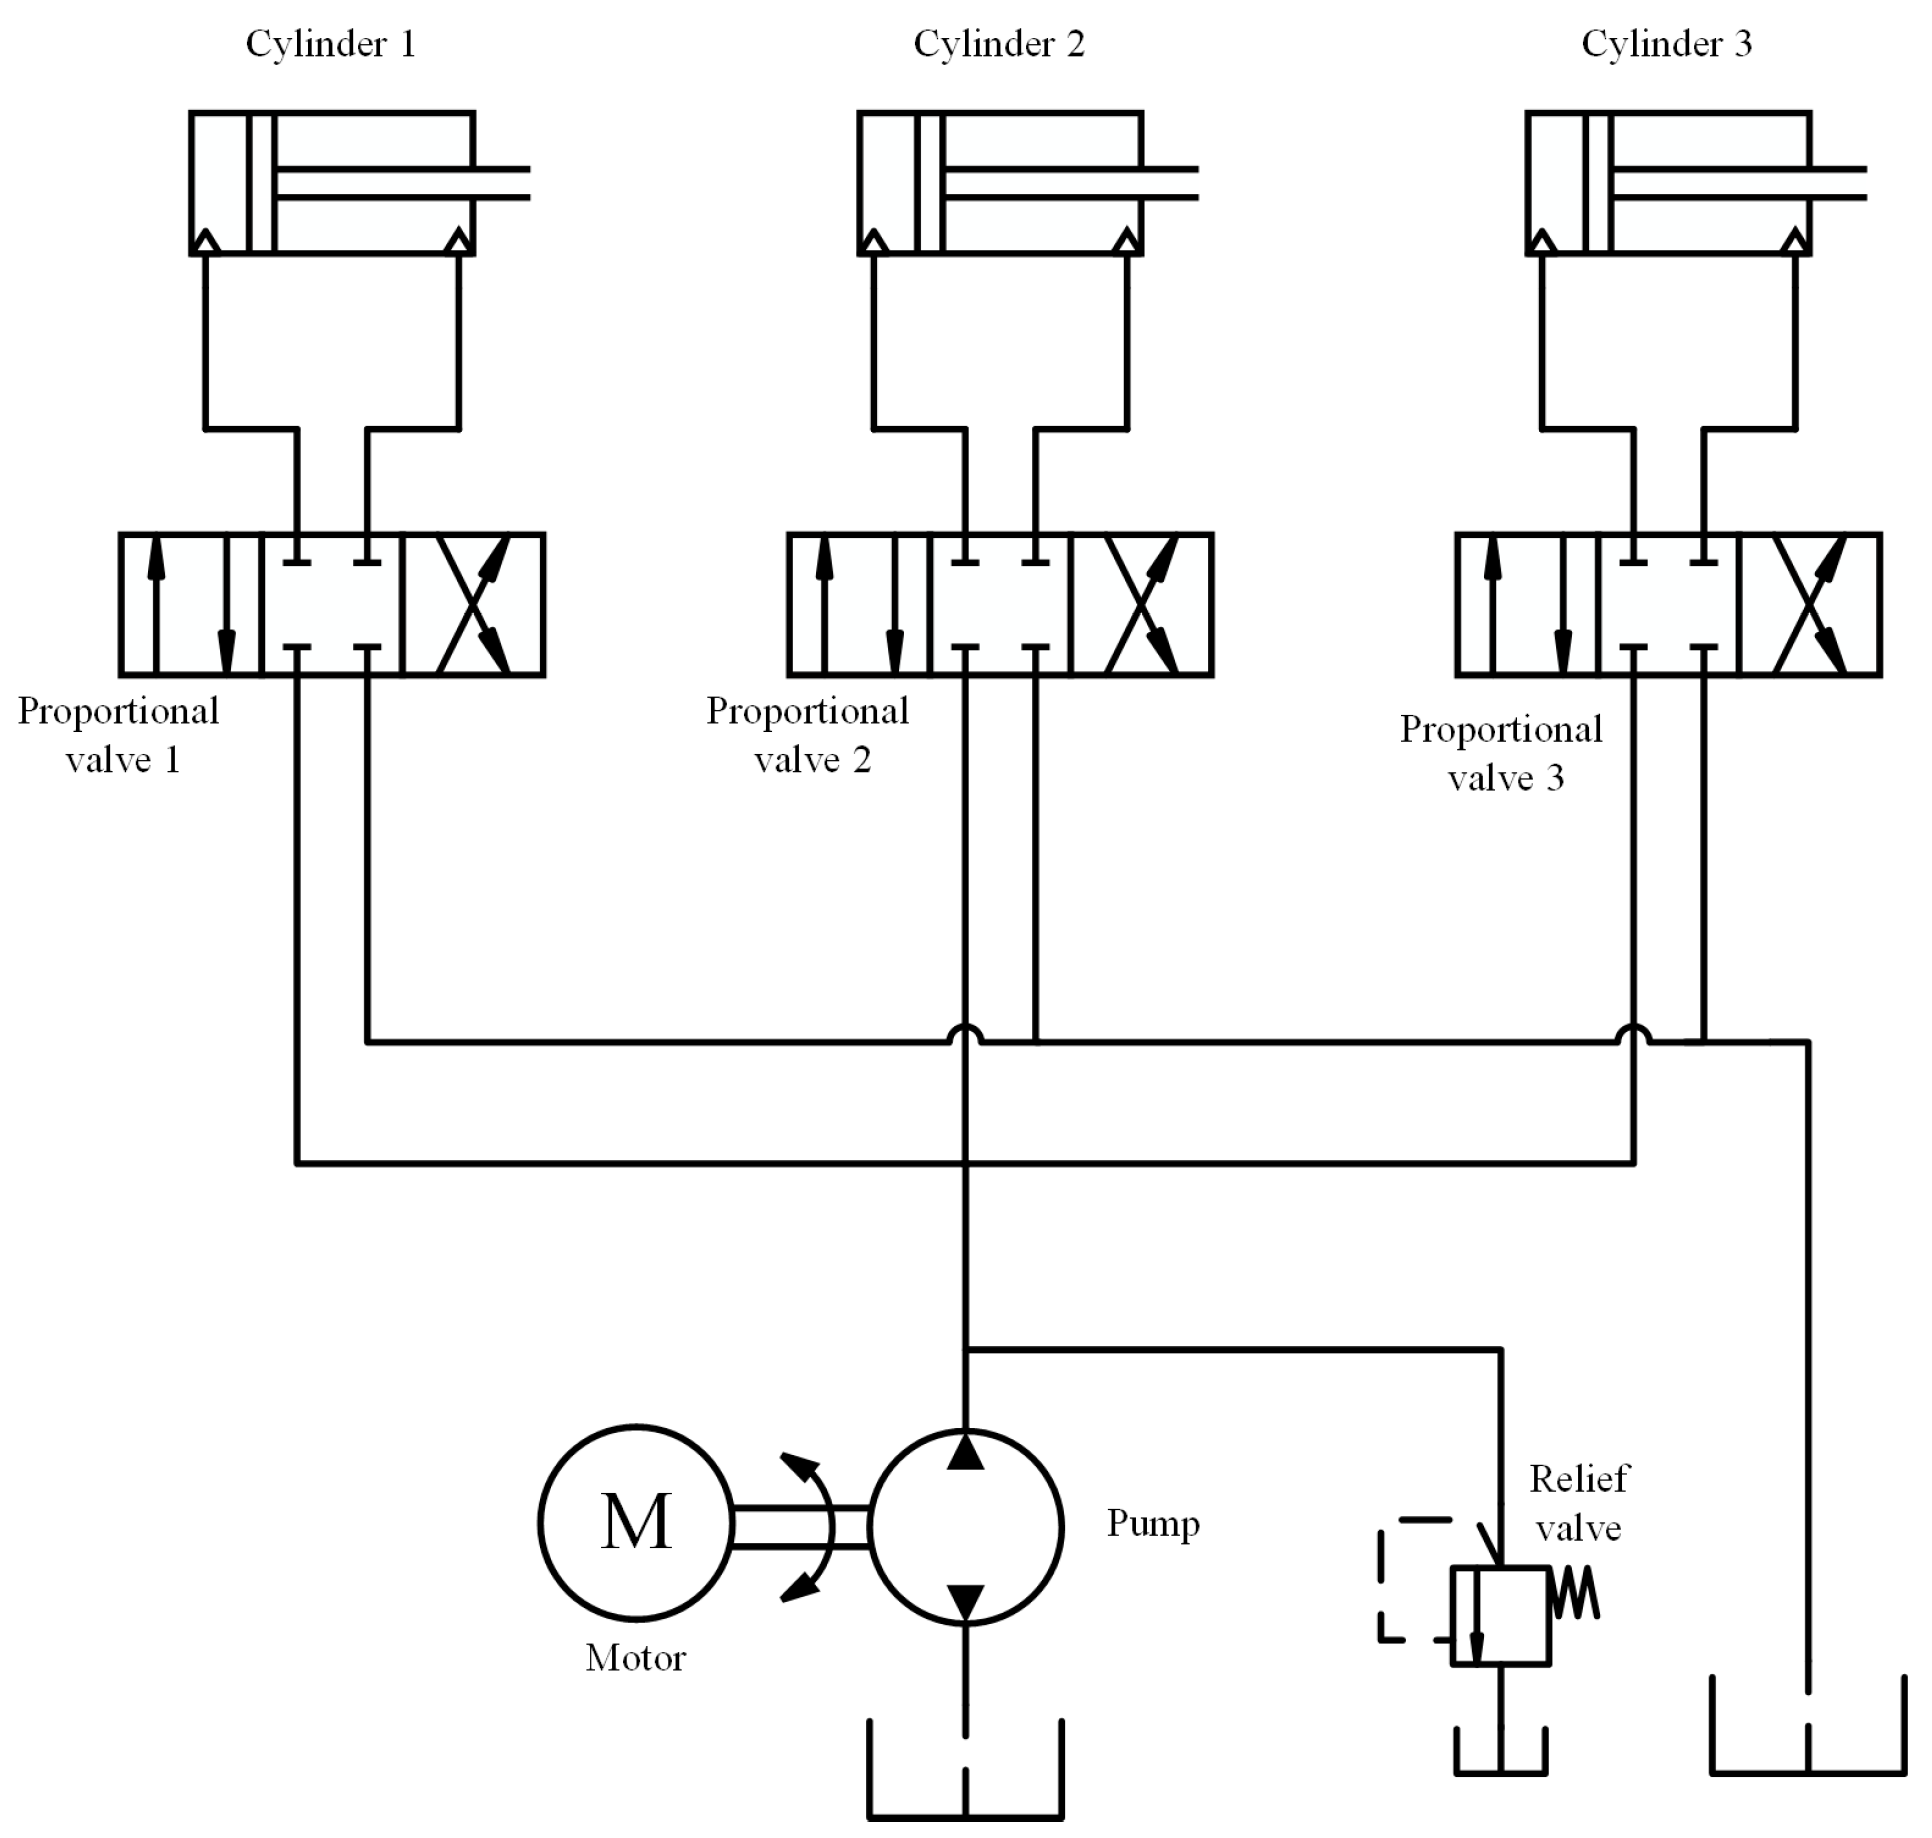
2.2. Hydraulic Dynamics Modeling of Multi-Joint Robotic Manipulator Systems
2.3. Dynamics of the Coupled Model for the Hydraulic–Mechanical System with a Multi-Joint Robotic Manipulator
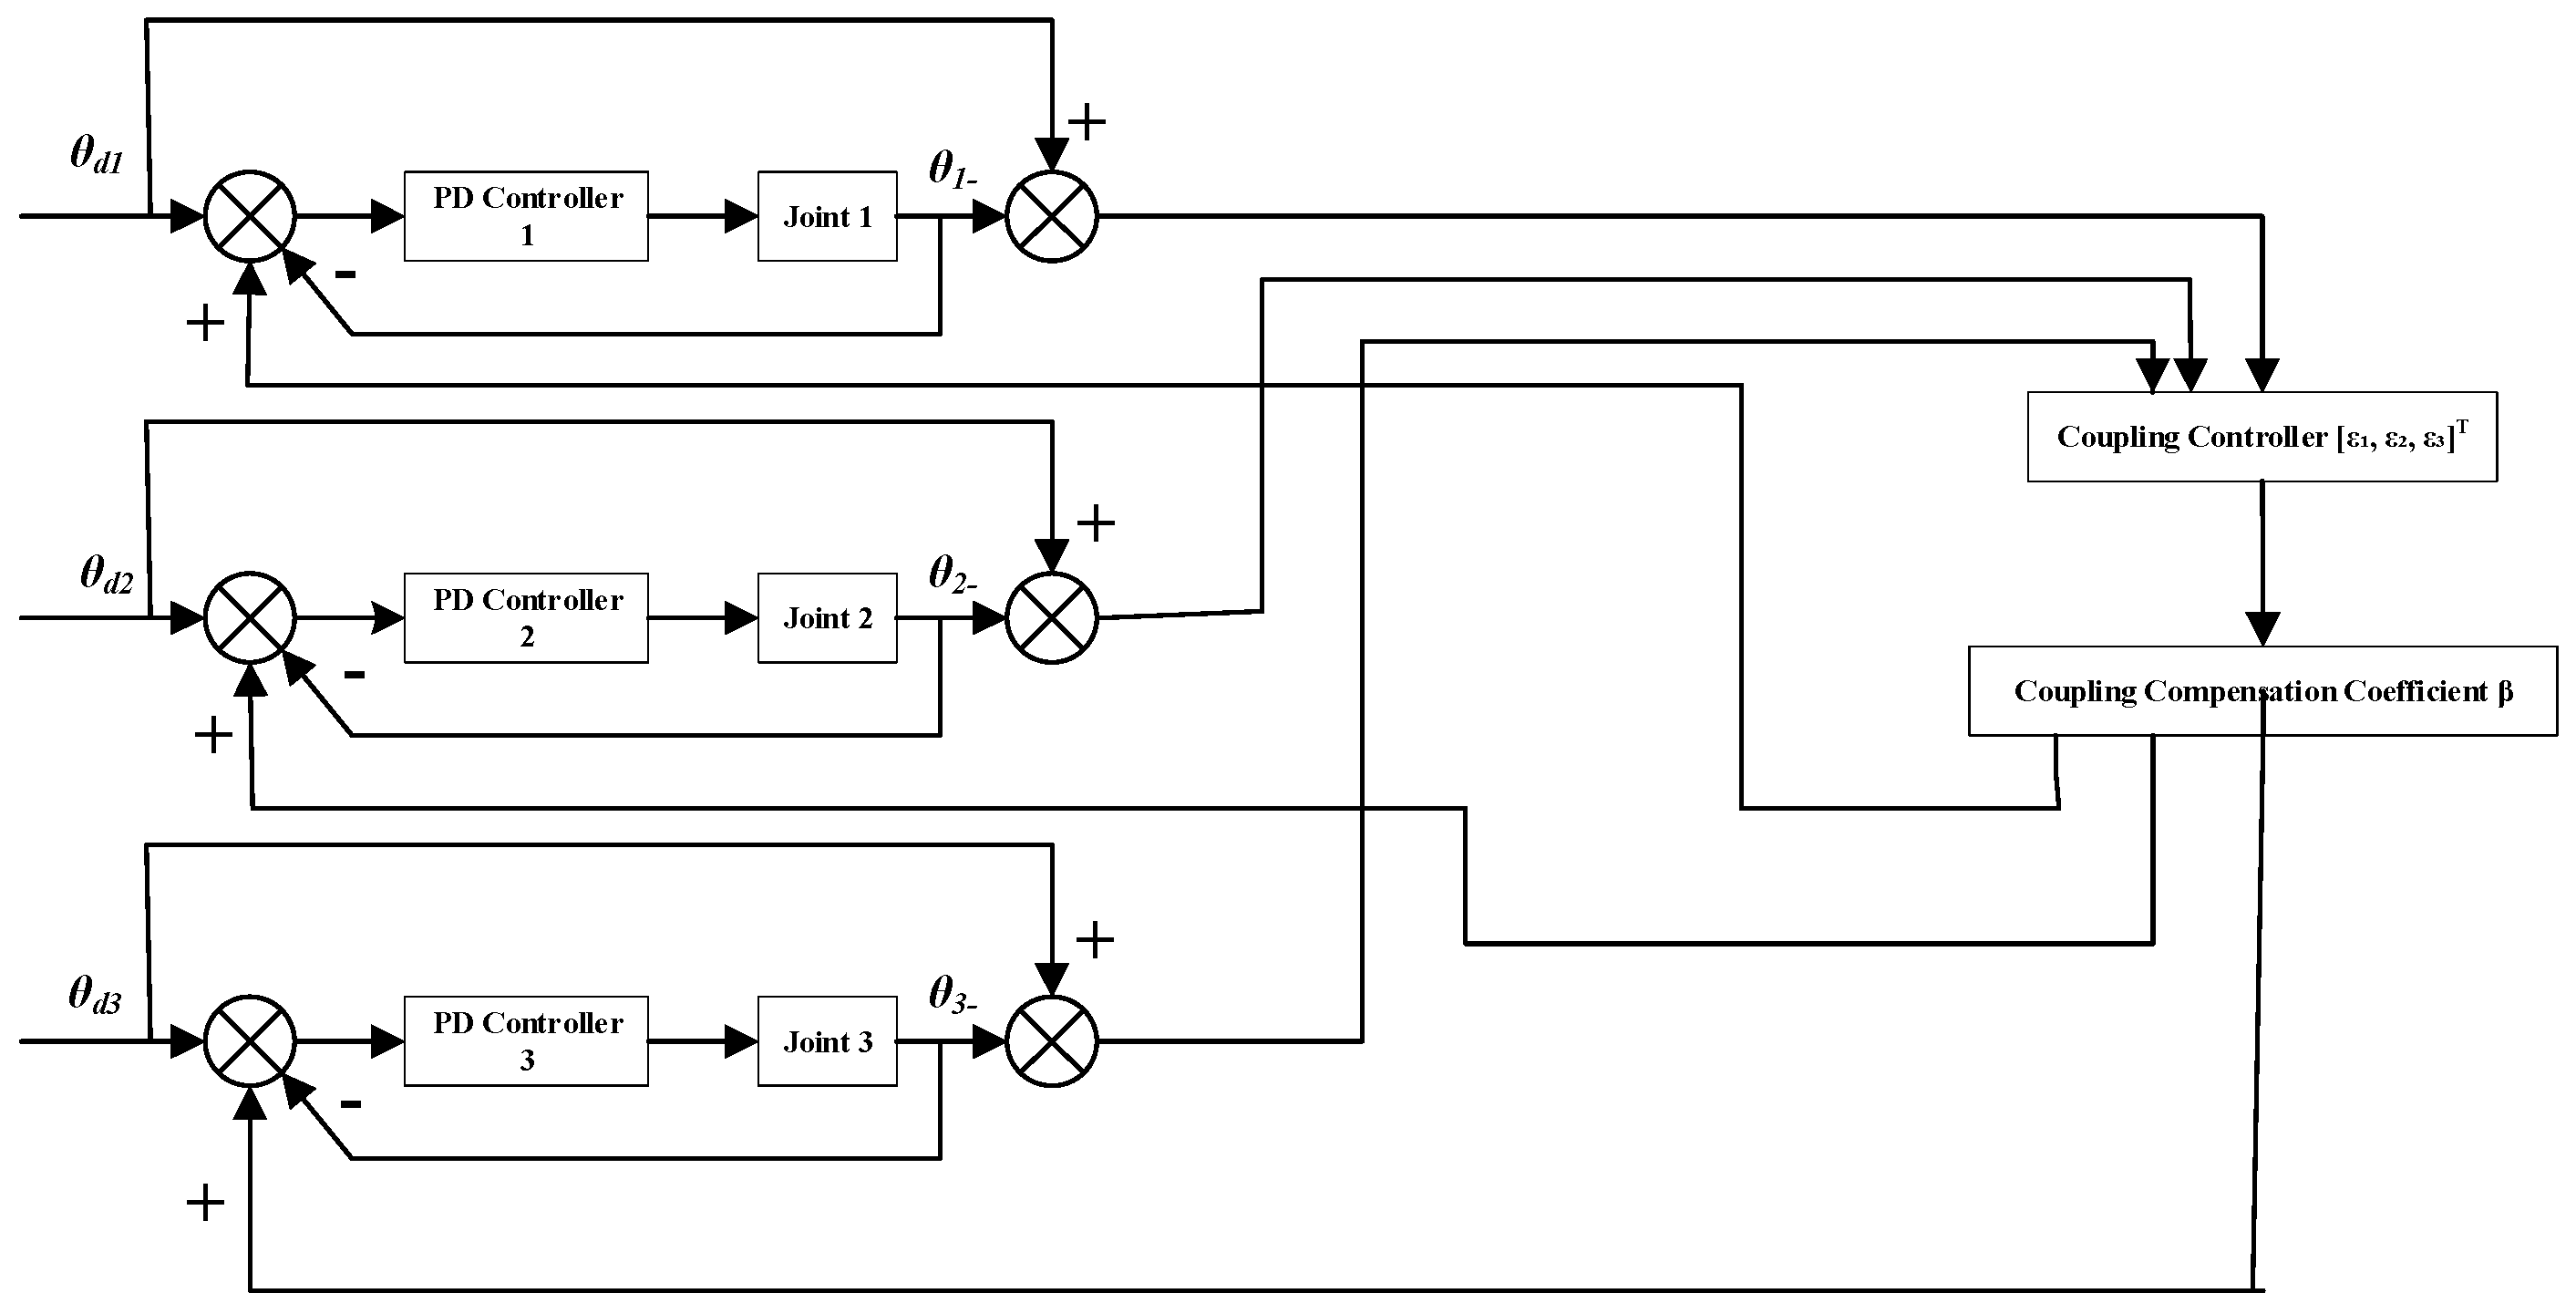
3. Design of Improved Deviation Coupling Control Strategy
3.1. Design of the Controller
3.2. Stability Analysis
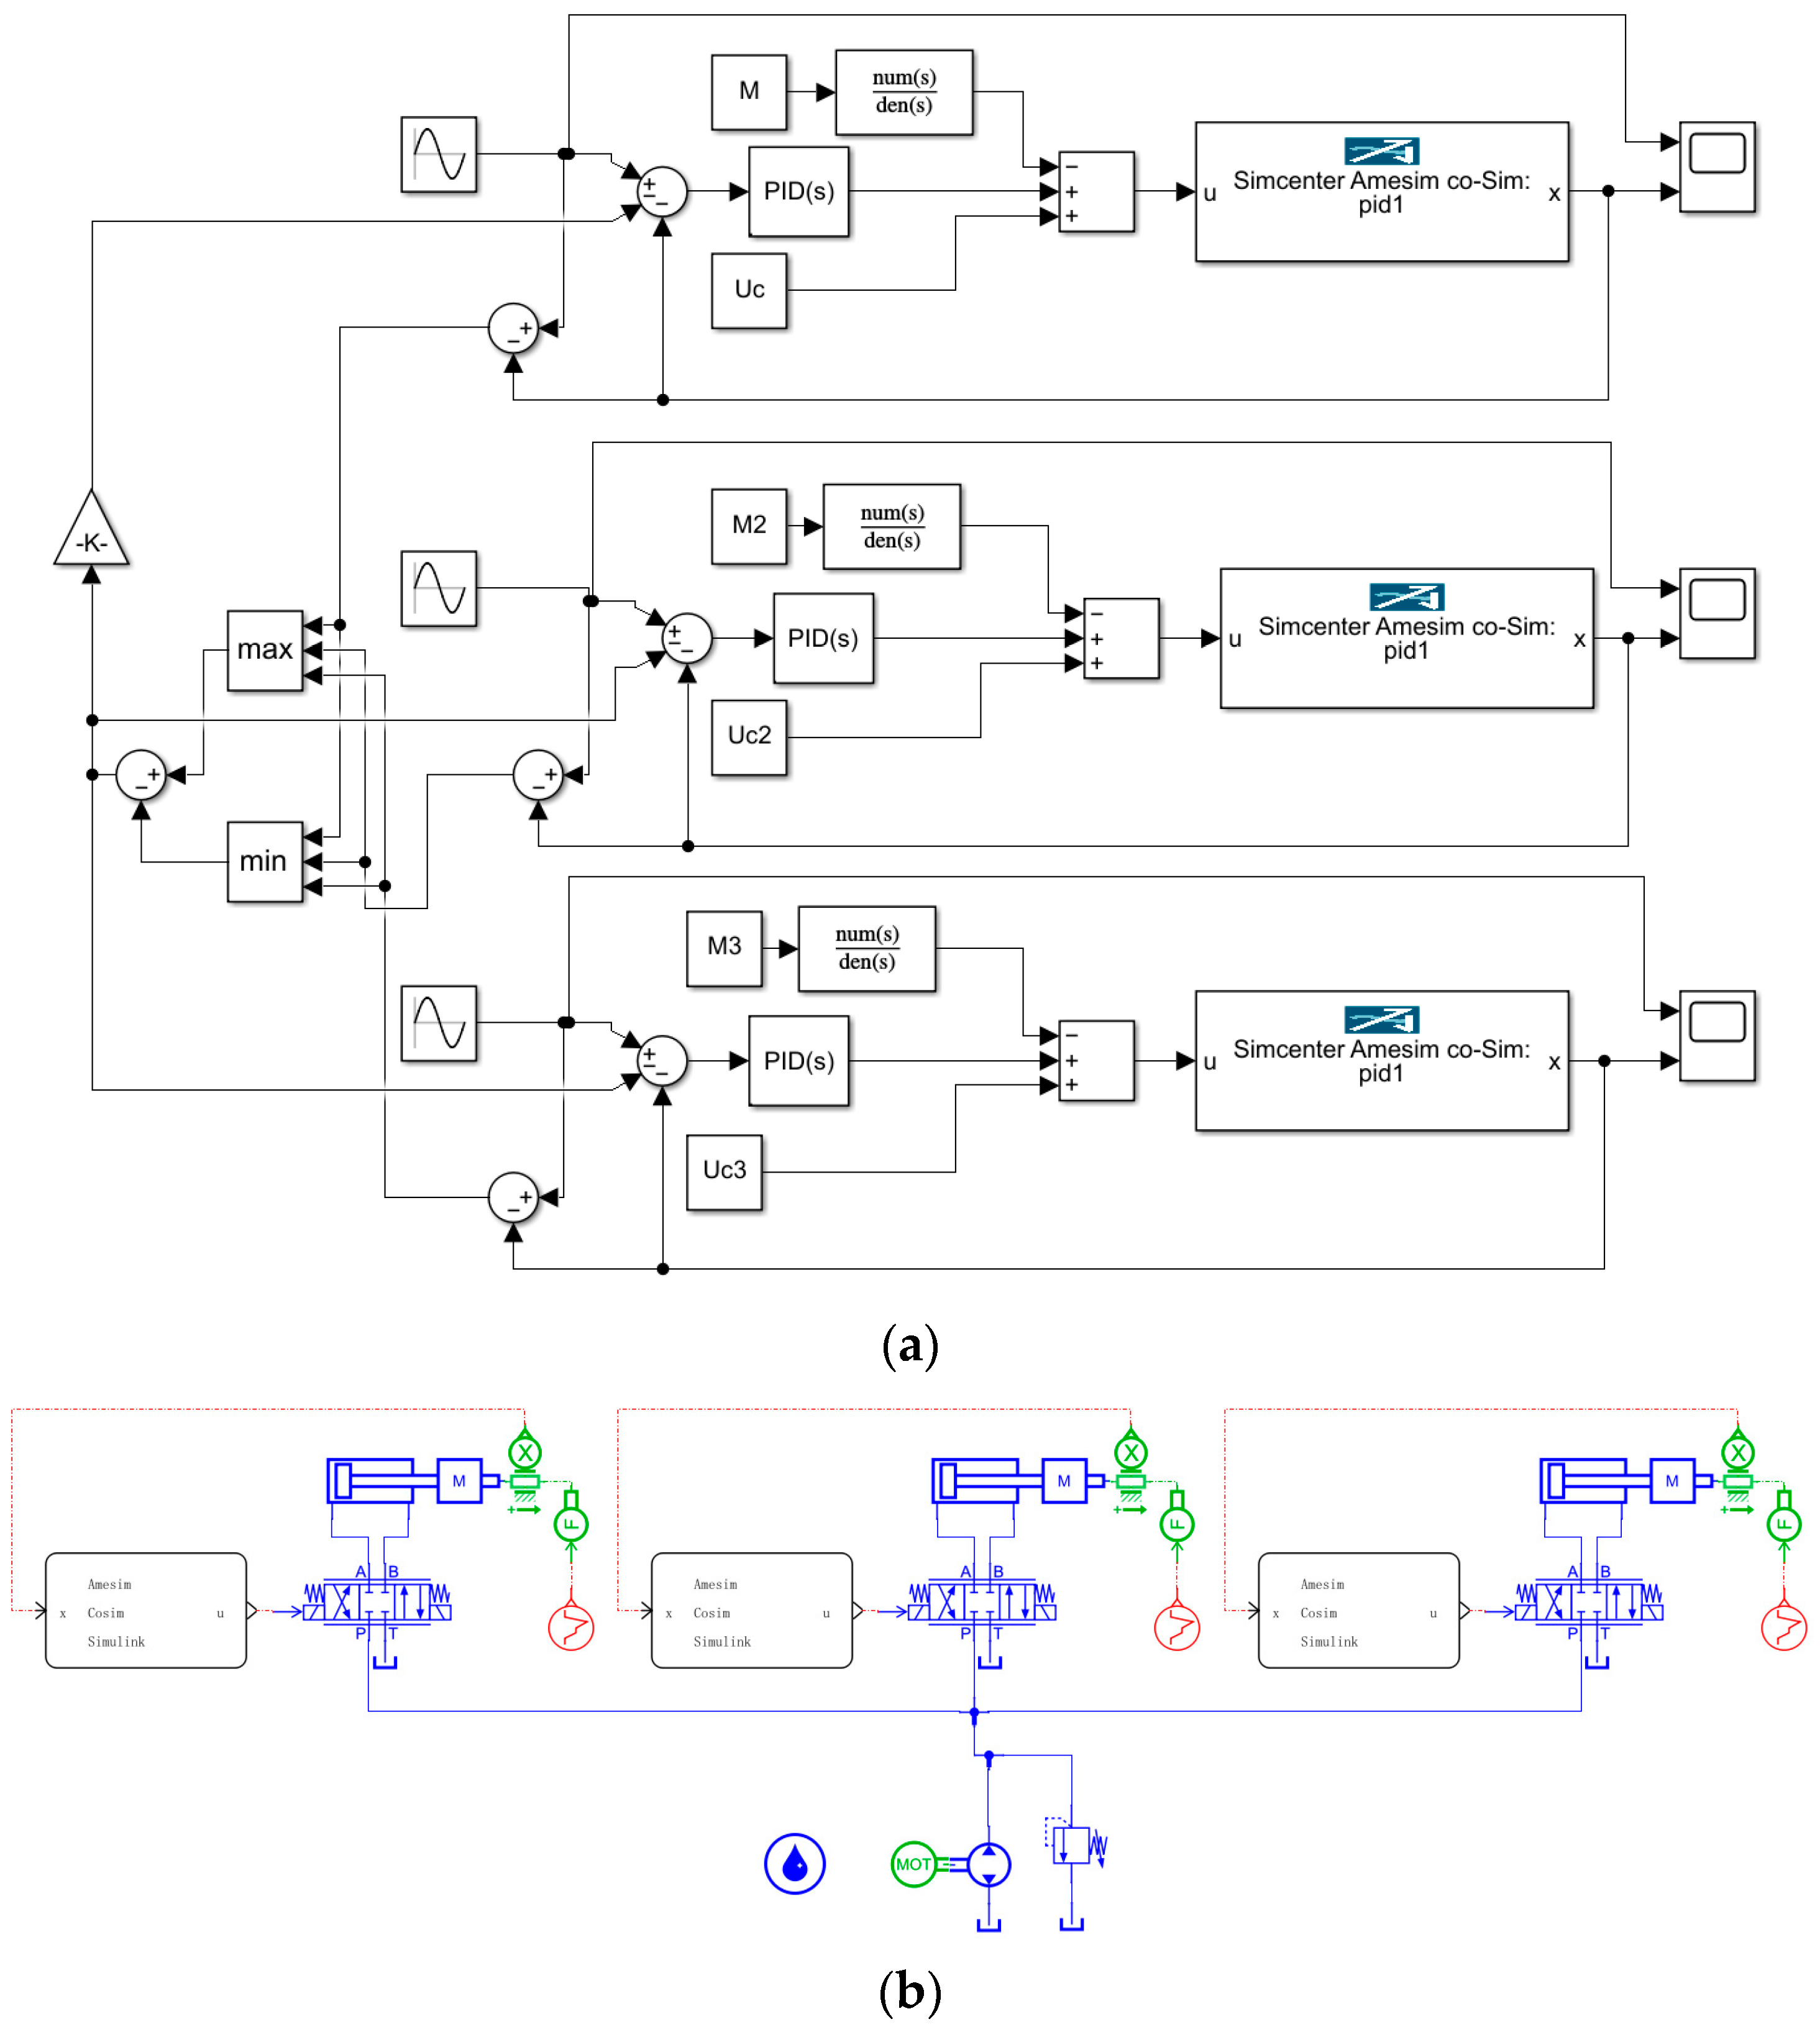
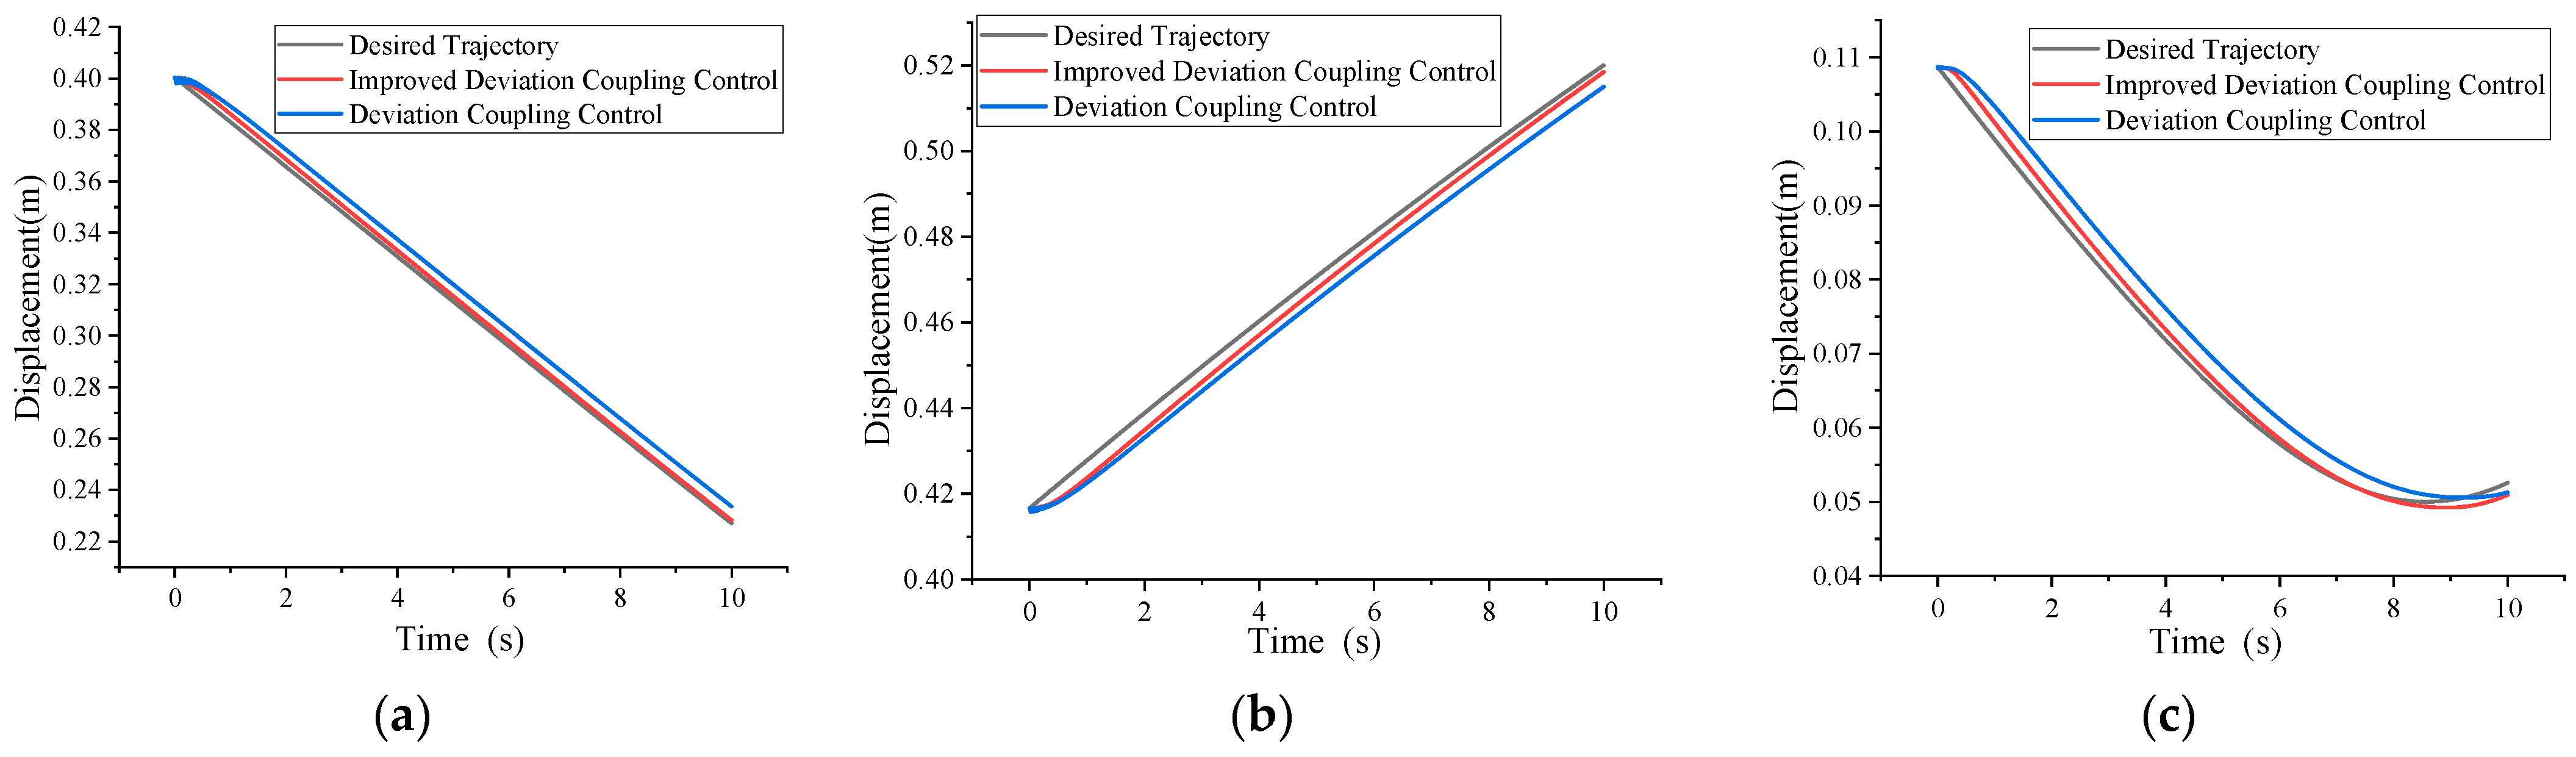
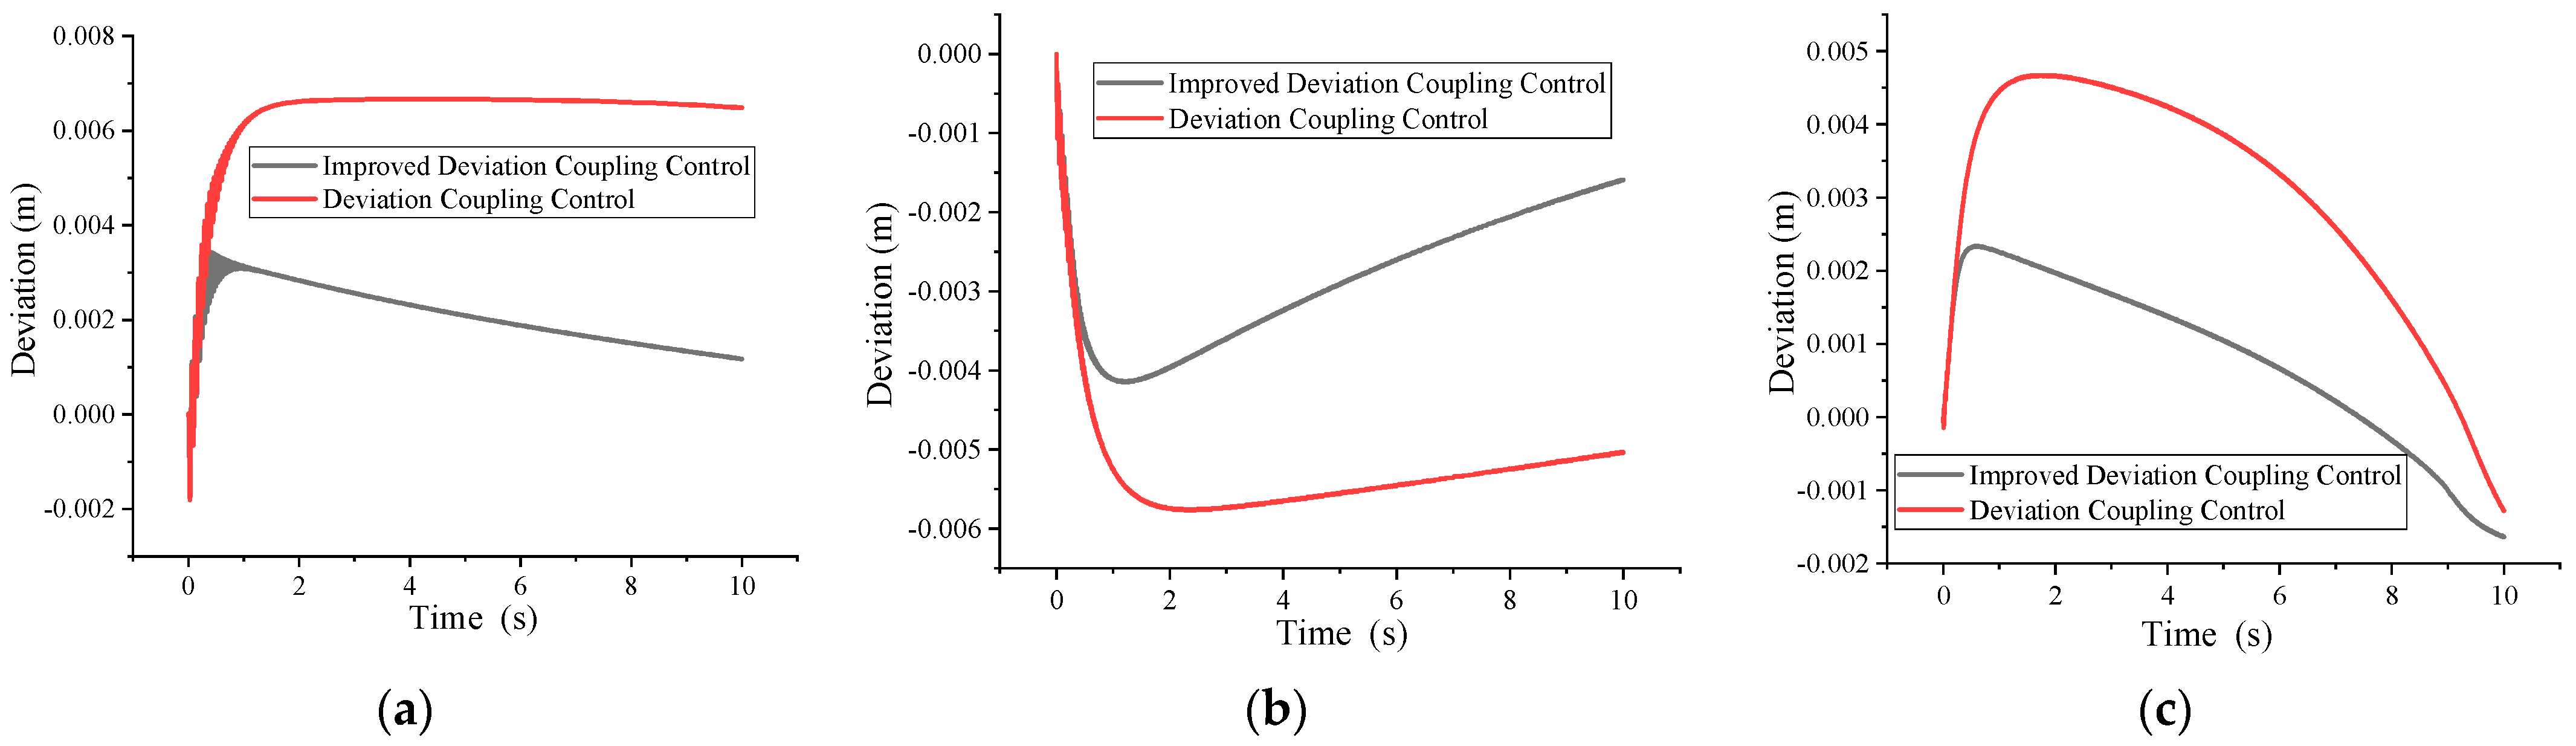
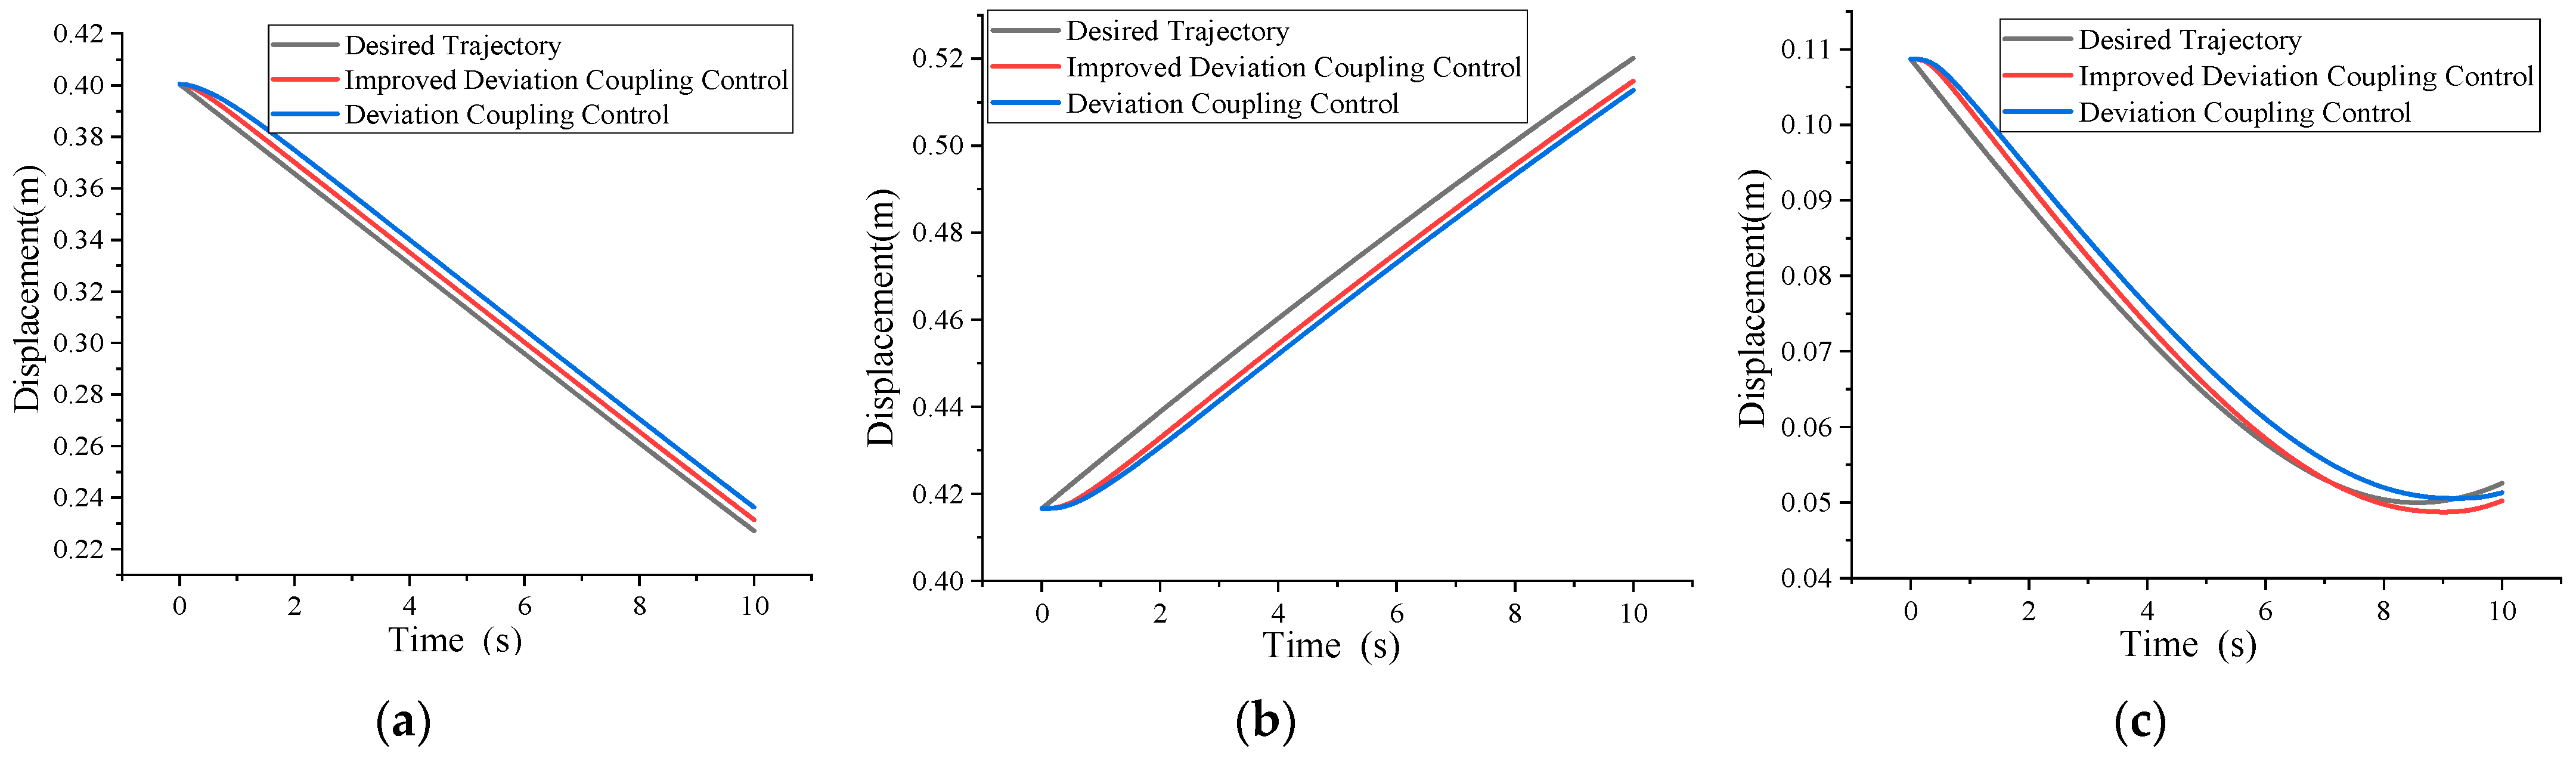
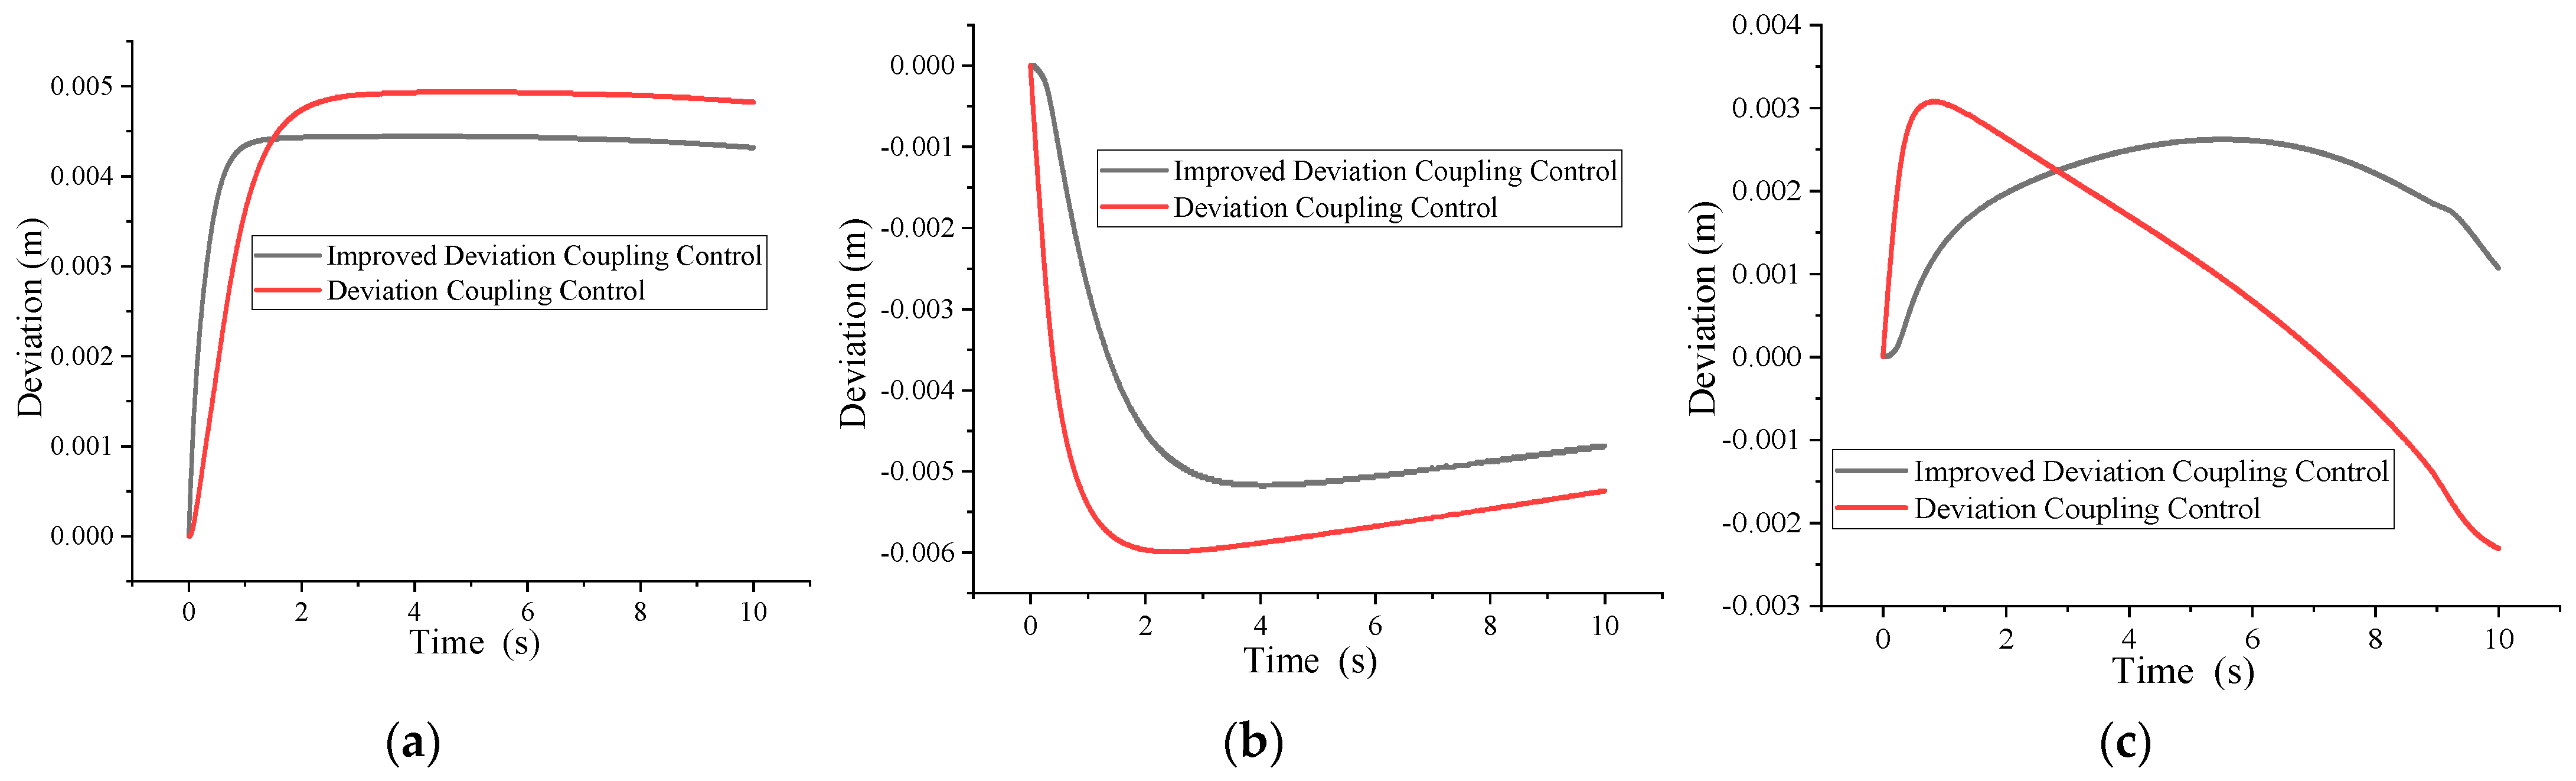
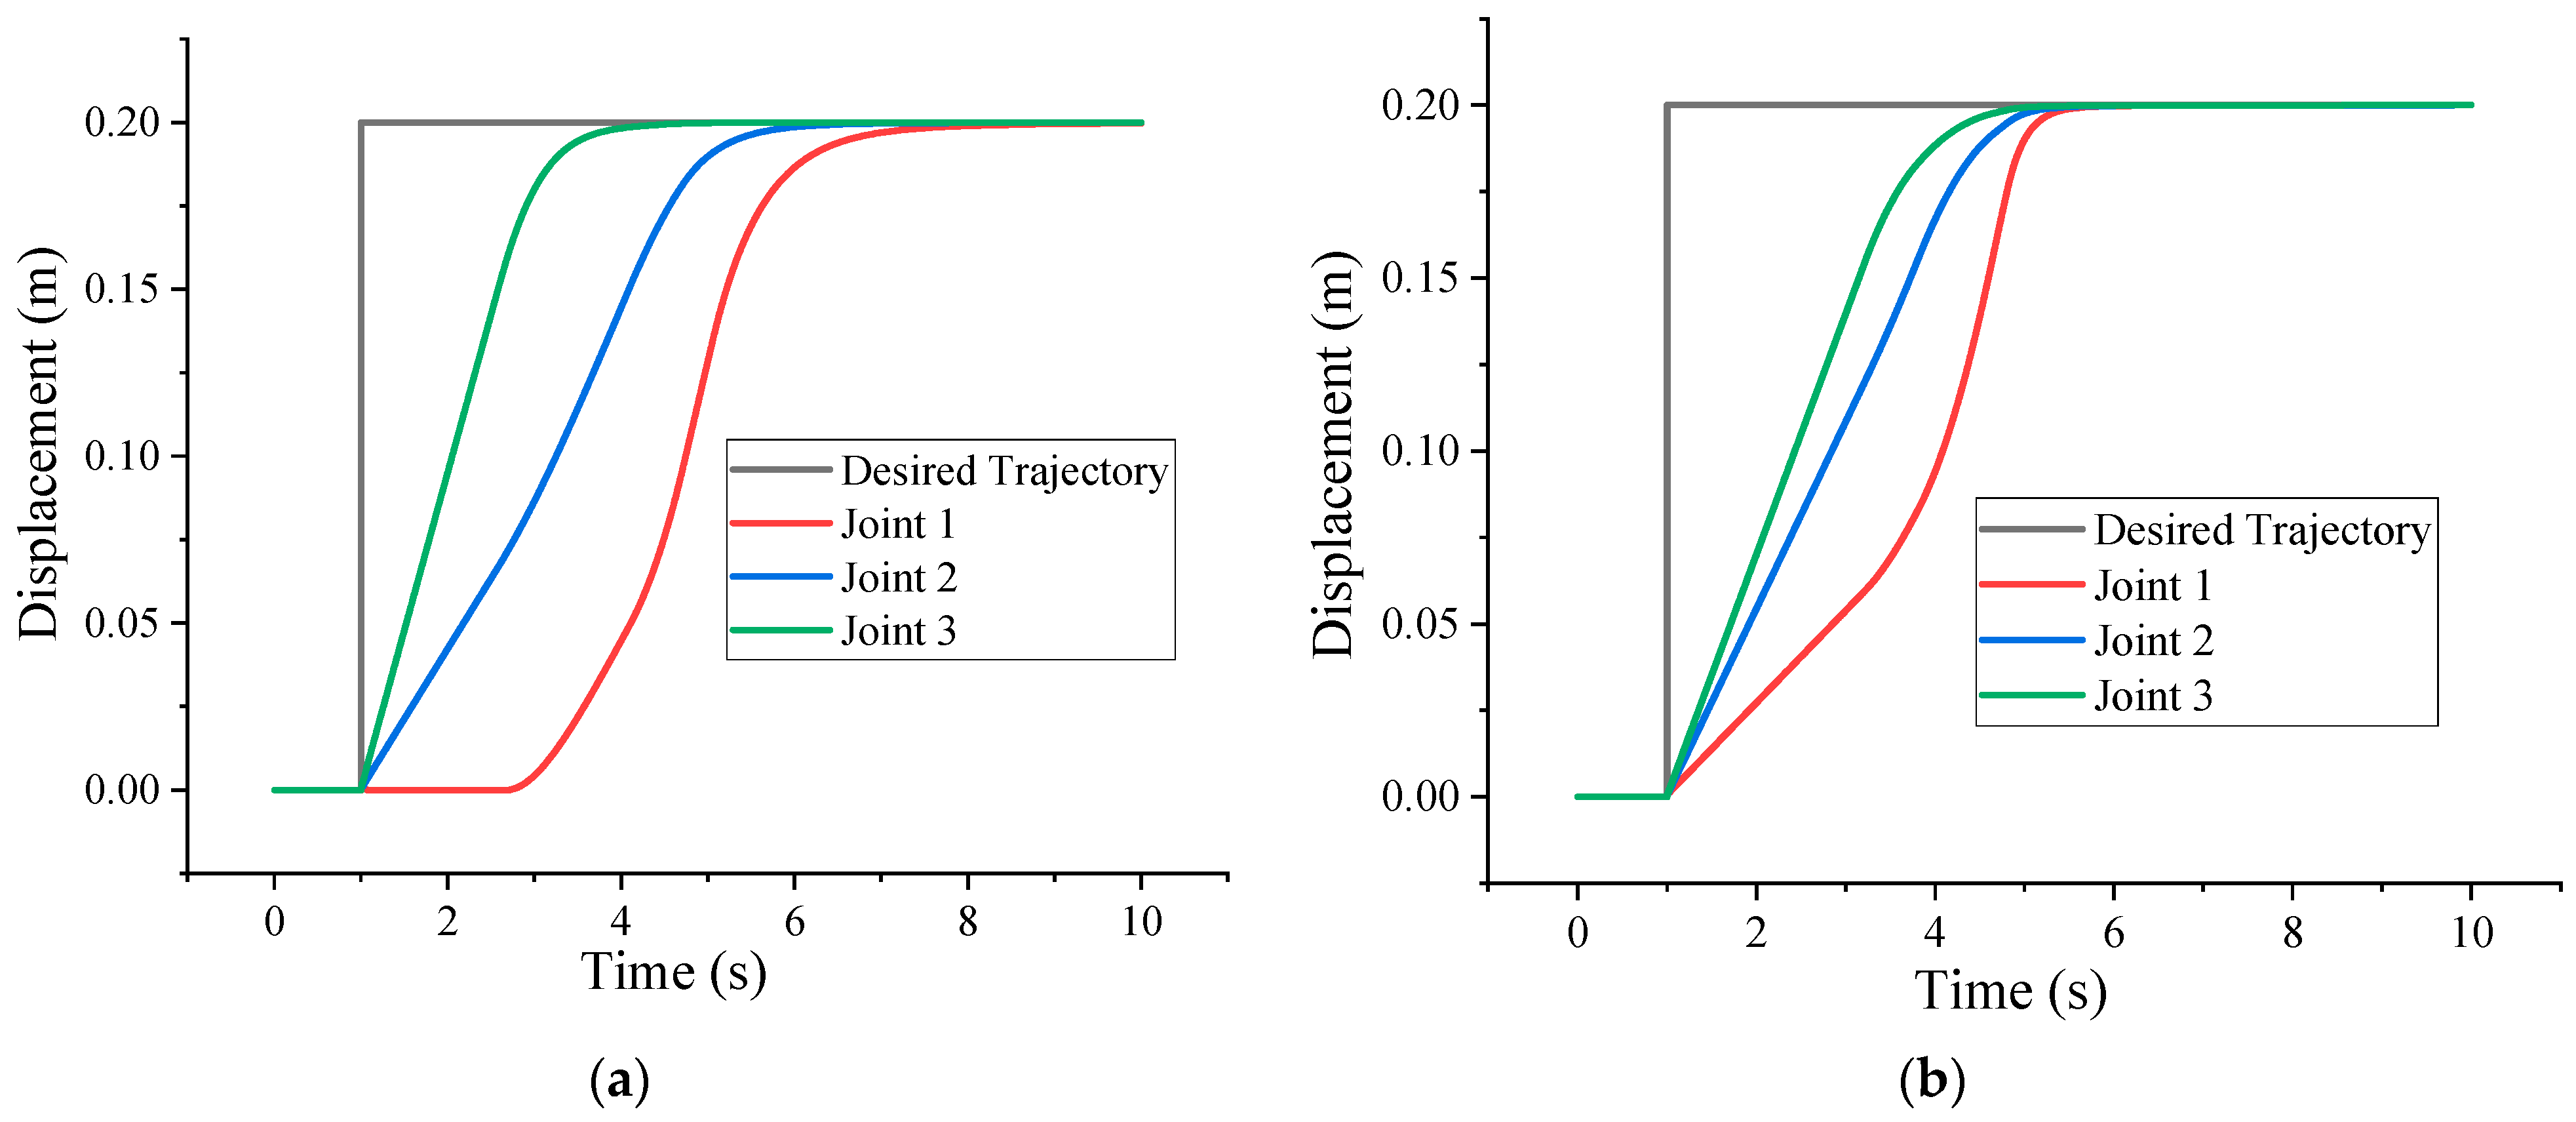
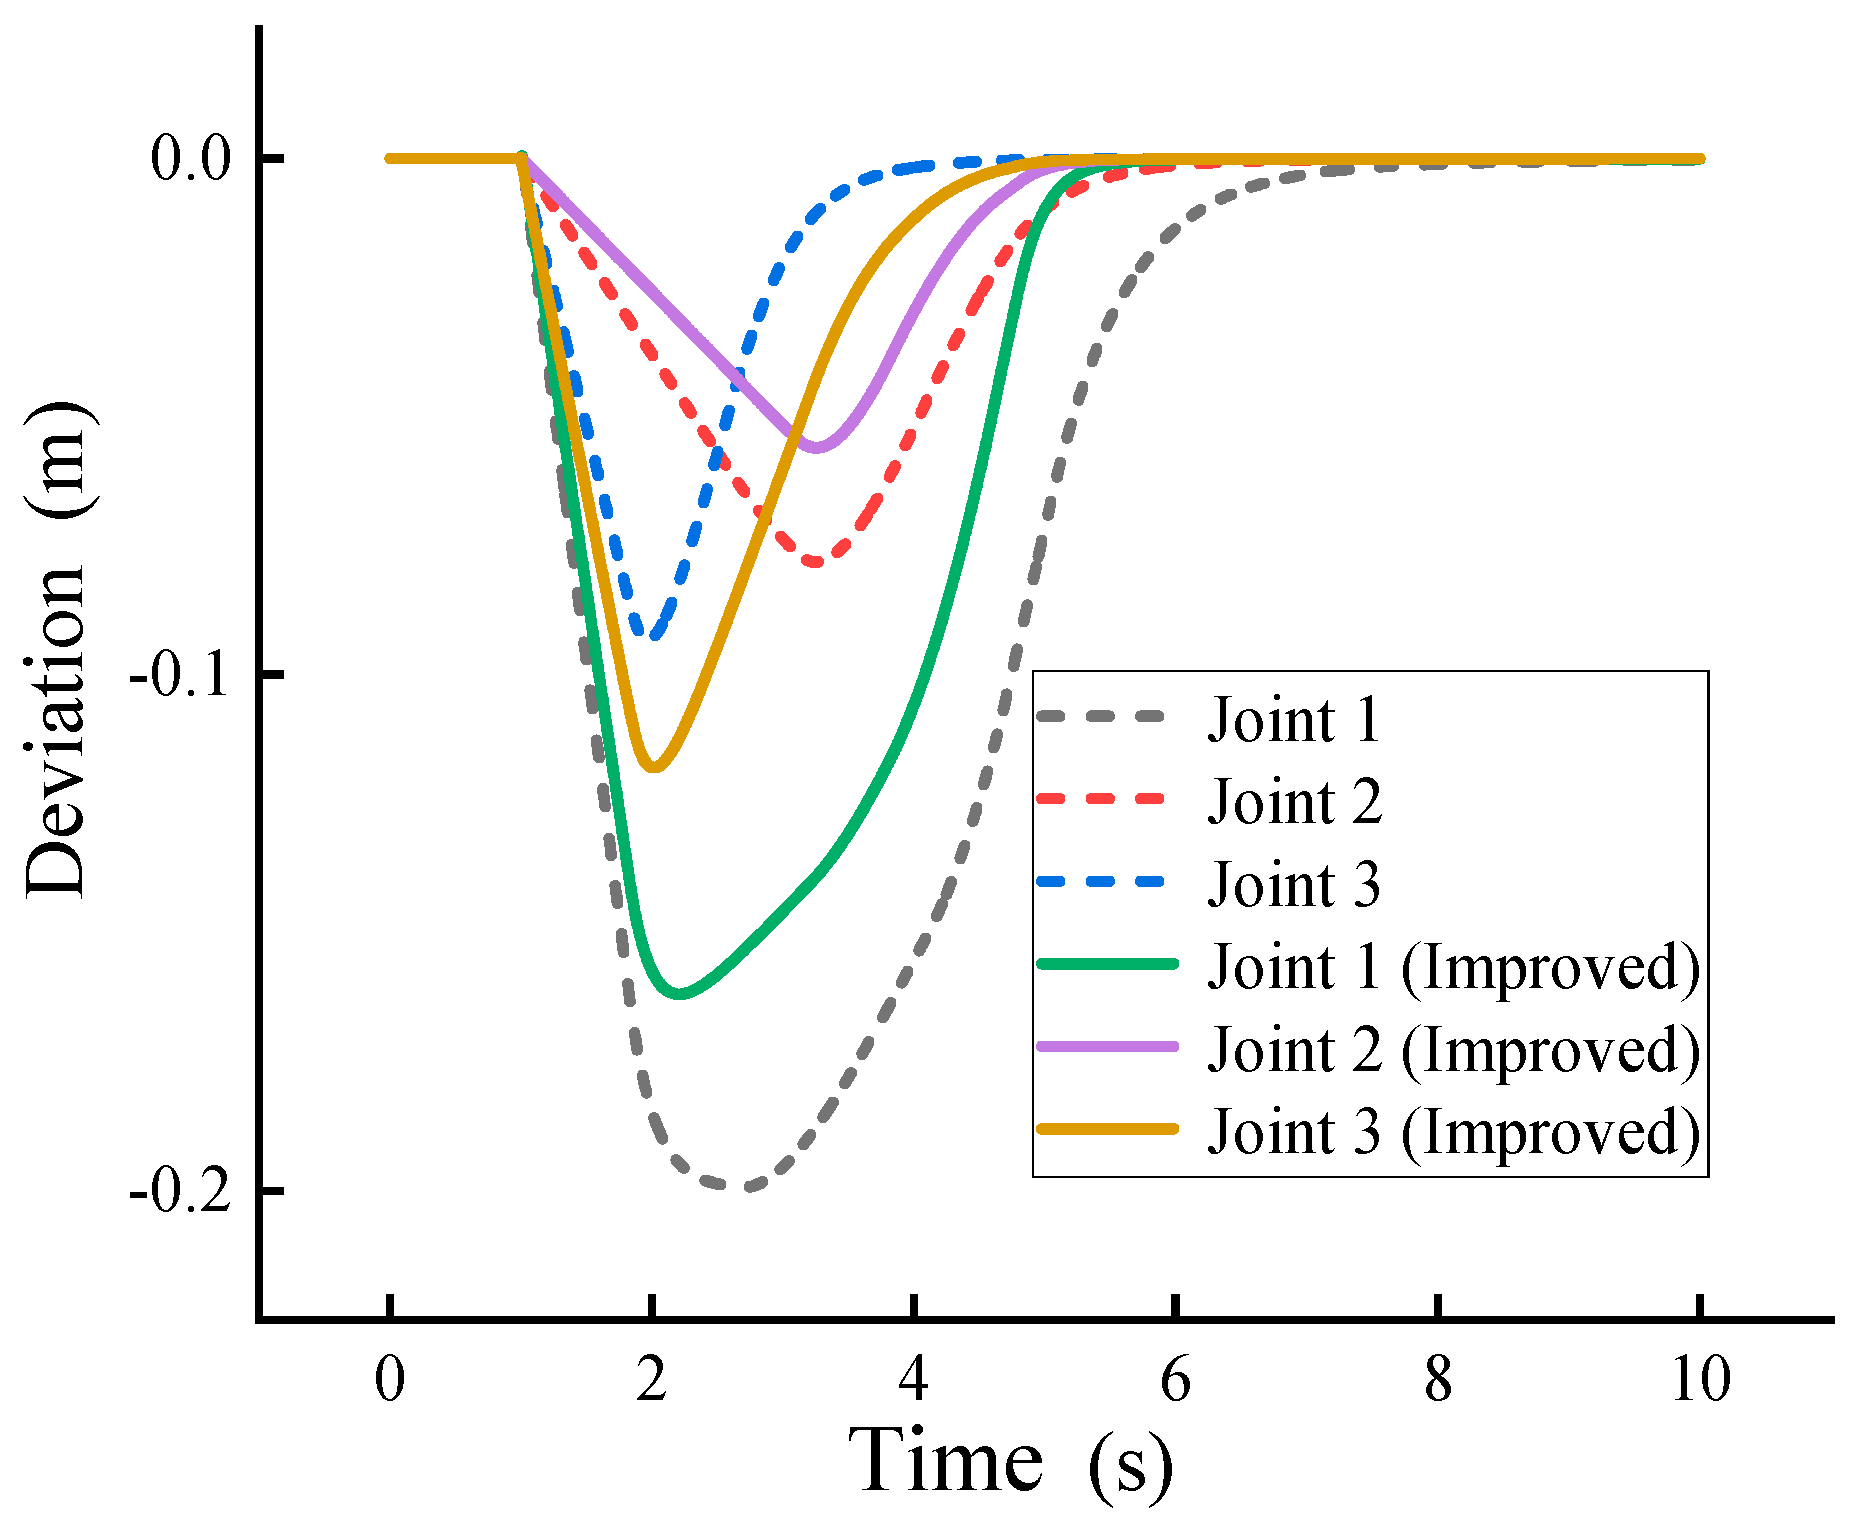
4. Simulation Analysis of Multi-Joint Synchronous Control Strategy
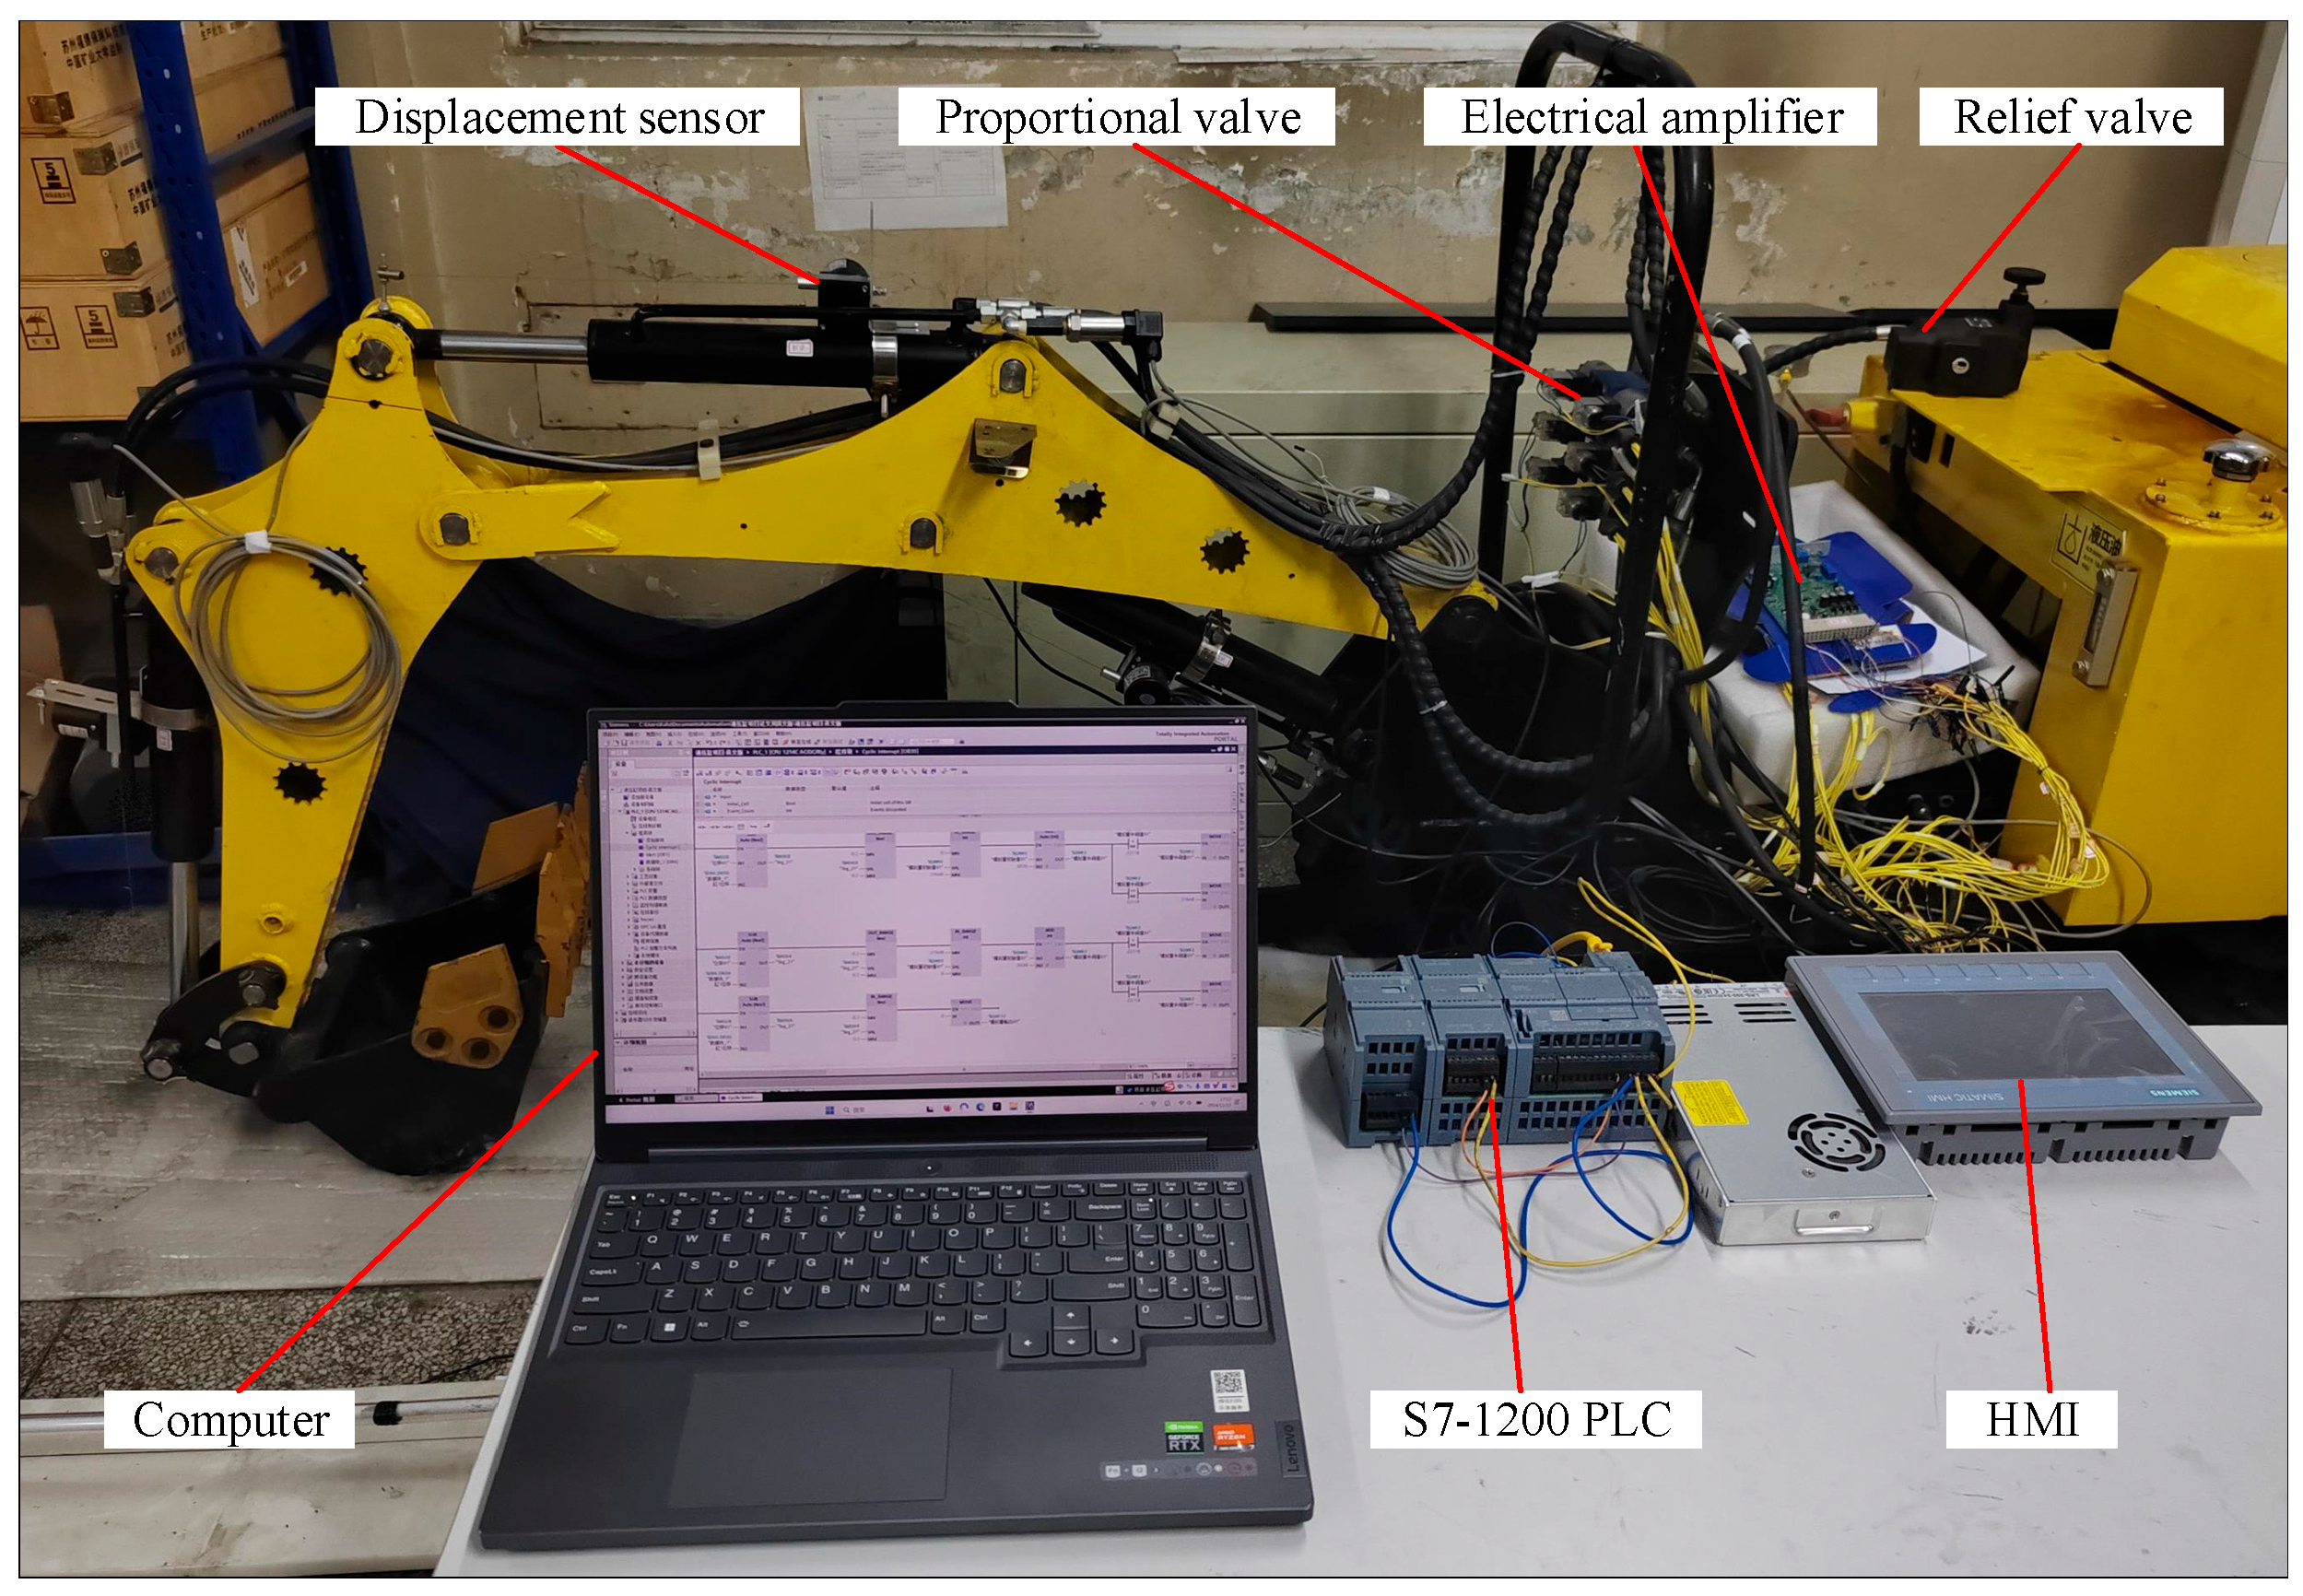
5. Experimental Verification
6. Conclusions
Author Contributions
Funding
Data Availability Statement
Acknowledgments
Conflicts of Interest
References
- Onifade, M.; Said, K.O.; Shivute, A.P. Safe mining operations through technological advancement. Process Saf. Environ. Prot. 2023, 175, 251–258. [Google Scholar] [CrossRef] [Scilit]
- Ralston, J.; Reid, D.; Hargrave, C.; Hainsworth, D. Sensing for advancing mining automation capability: A review of underground automation technology development. Int. J. Min. Sci. Technol. 2014, 24, 305–310. [Google Scholar] [CrossRef] [Scilit]
- Mariz, J.L.V.; Badiozamani, M.M.; Peroni, R.L.; de Abreu Silva, R.M. A critical review of bench aggregation and mining cut clustering techniques based on optimization and artificial intelligence to enhance the open-pit mine planning. Eng. Appl. Artif. Intell. 2024, 133, 108334. [Google Scholar] [CrossRef] [Scilit]
- Raza, M.; Karim, A.; Aman, M.; Al-Khasawneh, M.A.; Faheem, M. Global progress towards the Coal: Tracking coal reserves, coal prices, electricity from coal, carbon emissions and coal phase-out. Gondwana Res. 2025, 139, 43–72. [Google Scholar] [CrossRef] [Scilit]
- Peng, S.; Guo, W.; Li, Y. Chinese coal industry and coal mining engineering education. Min. Eng. 2024, 76, 34–38. [Google Scholar]
- Li, D.; Peng, S.; Guo, Y.; Lin, P. Development status and prospect of geological guarantee technology for intelligent coal mining in China. Green Smart Min. Eng. 2024, 1, 433–446. [Google Scholar] [CrossRef] [Scilit]
- Liu, P.; Zhou, H.; Qiao, X.; Zhu, Y. On the relative kinematics and control of dual-arm cutting robots for a coal mine. Actuators 2024, 13, 157. [Google Scholar] [CrossRef] [Scilit]
- Sun, S.; Meng, X.; Xu, X. Research on obstacle-avoidance trajectory planning for drill and anchor materials handling by a mechanical arm on a coal mine drilling and anchoring robot. Sensors 2024, 24, 6866. [Google Scholar] [CrossRef] [Scilit]
- Wang, J.; Huang, Z. The recent technological development of intelligent mining in China. Engineering 2017, 3, 439–444. [Google Scholar] [CrossRef] [Scilit]
- Ghoshal, S.K.; Pandey, A.K.; Dasgupta, K.; Bhola, M. A segmental pump-motor control scheme to attain targeted speed under varying load demand of a hydraulic drive used in heavy earth movers. Mechatronics 2021, 80, 102681. [Google Scholar] [CrossRef] [Scilit]
- Wu, H. Simulation analysis of hydraulic control system of engineering robot arm based on ADAMS. Int. J. Adv. Comput. Sci. Appl. 2023, 14, 414–420. [Google Scholar] [CrossRef] [Scilit]
- Zhong, J.; Jiang, W.; Zhang, Q.; Zhang, W. Design and simulation of a seven-degree-of-freedom hydraulic robot arm. Actuators 2023, 12, 362. [Google Scholar] [CrossRef] [Scilit]
- Guo, Q.; Yu, T.; Jiang, D. Robust H∞ positional control of 2-DOF robotic arm driven by electro-hydraulic servo system. ISA Trans. 2015, 59, 55–64. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Xu, J.; Sui, Z.; Wei, X. Singular perturbation decoupling and composite control scheme for hydraulically driven flexible robotic arms. Processes 2025, 13, 1805. [Google Scholar] [CrossRef] [Scilit]
- Majstorovic, V.; Simeunovic, V.; Miskovic, Z.; Mitrovic, R.; Stosic, D.; Dimitrijevic, S. Smart manufacturing as a framework for smart mining. Procedia CIRP 2021, 104, 188–193. [Google Scholar] [CrossRef] [Scilit]
- Wang, G.; Pang, Y.; Ren, H.; Zhan, K.; Du, M.; Zhang, Y.; Cheng, J.; Du, Y.; Zhang, J.; Gong, S.; et al. System engineering and key technologies research and practice of smart mine. J. China Coal Soc. 2024, 49, 181–202. [Google Scholar]
- Ren, Z.; Chen, J.; Miao, Y.; Miao, Y.; Guo, Z.; Hu, B.; Lin, R. Adaptive sliding mode control of robotic manipulator based on reinforcement learning. Asian J. Control 2024, 26, 2703–2718. [Google Scholar] [CrossRef] [Scilit]
- Karahan, O.; Karci, H. Design of robust fractional order fuzzy PID sliding mode controller based on hybrid swarm intelligence algorithm for a 6-DOF robotic manipulator. Robotica 2025, 43, 1110–1139. [Google Scholar] [CrossRef] [Scilit]
- Wei, X.; Wangm, Z.; Li, J.; Yin, H. Hybrid neural network adaptive fuzzy sliding mode online compensatory control for robots with global stability. Neurocomputing 2025, 657, 131632. [Google Scholar] [CrossRef] [Scilit]
- Sutyasadi, P.; Wicaksono, M.B. Robotic arm joint position control using iterative learning and mixed sensitivity H∞ robust controller. Bull. Electr. Eng. Inform. 2021, 10, 1864–1873. [Google Scholar] [CrossRef] [Scilit]
- Xue, Y.; Wang, B.; Xu, J.; Sun, Q.; Zhang, P. Research on multi-cylinder coordinated coupling synchronous control strategy based on strain energy. Sci. Rep. 2025, 15, 44277. [Google Scholar] [CrossRef] [Scilit]
- Wos, P.; Dindorf, R. Synchronized trajectory tracking control of 3-DoF hydraulic translational parallel manipulator. Adv. Intell. Syst. Comput. 2015, 317, 269–277. [Google Scholar]
- Lefeber, A.A.J.; Daerden, F.; Vanderborght, B. Coordinated Control of Hydraulic Mobile Manipulators. IFAC Proc. Vol. 2012, 45, 435–440. [Google Scholar] [CrossRef] [Scilit]
- Mu, Y.; Qi, L.; Sun, M.; Han, W. An improved deviation coupling control method for speed synchronization of multi-motor systems. Appl. Sci. 2024, 14, 5300. [Google Scholar] [CrossRef] [Scilit]
- Zhao, W.; Bhola, M.; Ebbesen, M.K.; Andersen, T.O. A novel control design for realizing passive load-holding function on a two-motor-two-pump motor-controlled hydraulic cylinder. Model. Identif. Control 2023, 44, 115–128. [Google Scholar]
- Petrović, G. Mathematical modelling and virtual decomposition control of heavy-duty parallel–serial hydraulic manipulators. Mech. Mach. Theory 2022, 170, 104680. [Google Scholar]
- Bao, Q.; Zhou, J.; Jing, C.; Zhao, H.; Wu, Y.; Zhang, Z. Nonlinear dynamic model for the free rotor of the swash plate-rotating hydraulic transformer. Energy 2022, 261, 125355. [Google Scholar] [CrossRef] [Scilit]
- Guo, X.; Wang, H.; Wang, L.; Liu, H. Adaptive neural network sliding mode control for serially connected hydraulic cylinders of a heavy-duty hydraulic manipulator. J. Mech. Sci. Technol. 2023, 37, 4123–4135. [Google Scholar] [CrossRef] [Scilit]
- Spong, M.W.; Hutchinson, S.; Vidyasagar, M. Robot Modeling and Control, 2nd ed.; Wiley: Hoboken, NJ, USA, 2020. [Google Scholar]
- Manring, N.D.; Fales, R.C. Hydraulic Control Systems, 2nd ed.; Wiley: Hoboken, NJ, USA, 2022. [Google Scholar]
- Habibi, S.; Goldenberg, A. Design of a new high-performance electrohydraulic actuator. IEEE/ASME Trans. Mechatron. 2000, 5, 158–164. [Google Scholar]
- Stosiak, M.; Karpenko, M.; Deptuła, A.; Urbanowicz, K.; Skačkauskas, P.; Cieślicki, R.; Deptuła, A. Modelling and Experimental Verification of the Interaction in a Hydraulic Directional Control Valve Spool Pair. Appl. Sci. 2023, 13, 458. [Google Scholar]
- Xu, B.; Ding, R.; Zhang, J.; Cheng, M.; Sun, T. Analysis and compensation for the cascade dead-zones in the proportional control valve. ISA Trans. 2017, 66, 393–403. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Ruijgrok, T.W.; Van der Vlist, H. On the Hamiltonian and Lagrangian formulation of classical dynamics for particles with spin. Phys. A Stat. Mech. Its Appl. 1980, 101, 571–580. [Google Scholar] [CrossRef] [Scilit]
- Mucchi, E.; Dalpiaz, G.; Rivola, A. Elastodynamic analysis of a gear pump. Part I: Pressure distribution and gear eccentricity. Mech. Syst. Signal Process. 2010, 24, 2160–2179. [Google Scholar] [CrossRef] [Scilit]
- Kim, S.; Murrenhoff, H. Measurement of Effective Bulk Modulus for Hydraulic Oil at Low Pressure. J. Fluids Eng. 2012, 134, 021201. [Google Scholar] [CrossRef] [Scilit]





| Parameter | Value |
|---|---|
| Motor RPM (r/min) | 1500 |
| Pump Displacement (cc/rev) | 10 |
| Proportional Valve Pressure Drop (bar) | 10 |
| Relief Valve Cracking Pressure (Mpa) | 8 |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Zhao, L.; Dai, J.; Xu, H.; Sun, M.; Li, X.; Chen, S. Integrated Dynamic Modeling and Improved Deviation Coupling Control for Synchronous Motion of Multi-Joint Hydraulic Robotic Arms. Machines 2026, 14, 326. https://doi.org/10.3390/machines14030326
Zhao L, Dai J, Xu H, Sun M, Li X, Chen S. Integrated Dynamic Modeling and Improved Deviation Coupling Control for Synchronous Motion of Multi-Joint Hydraulic Robotic Arms. Machines. 2026; 14(3):326. https://doi.org/10.3390/machines14030326
Chicago/Turabian StyleZhao, Longmei, Jianbo Dai, Haozhi Xu, Mingyuan Sun, Xiaoqi Li, and Shuren Chen. 2026. "Integrated Dynamic Modeling and Improved Deviation Coupling Control for Synchronous Motion of Multi-Joint Hydraulic Robotic Arms" Machines 14, no. 3: 326. https://doi.org/10.3390/machines14030326
APA StyleZhao, L., Dai, J., Xu, H., Sun, M., Li, X., & Chen, S. (2026). Integrated Dynamic Modeling and Improved Deviation Coupling Control for Synchronous Motion of Multi-Joint Hydraulic Robotic Arms. Machines, 14(3), 326. https://doi.org/10.3390/machines14030326