Article

Enhancing Human–Machine Collaboration: A Trust-Aware Trajectory Planning Framework for Assistive Aerial Teleoperation


1
National Key Laboratory of Avionics Integration and Aviation System-of-Systems Synthesis, China Aeronautical Radio Electronics Research Institute, Shanghai 201100, China
2
Department of Automation, University of Science and Technology of China, Hefei 230026, China
3
Institute of Artificial Intelligence, Hefei Comprehensive National Science Center, Hefei 230088, China
*
Author to whom correspondence should be addressed.
Machines 2025, 13(9), 876; https://doi.org/10.3390/machines13090876

Submission received: 14 August 2025 / Revised: 14 September 2025 / Accepted: 17 September 2025 / Published: 20 September 2025
(This article belongs to the Special Issue Advances in AI-Powered Human–Machine-Augmented Intelligence)

Abstract

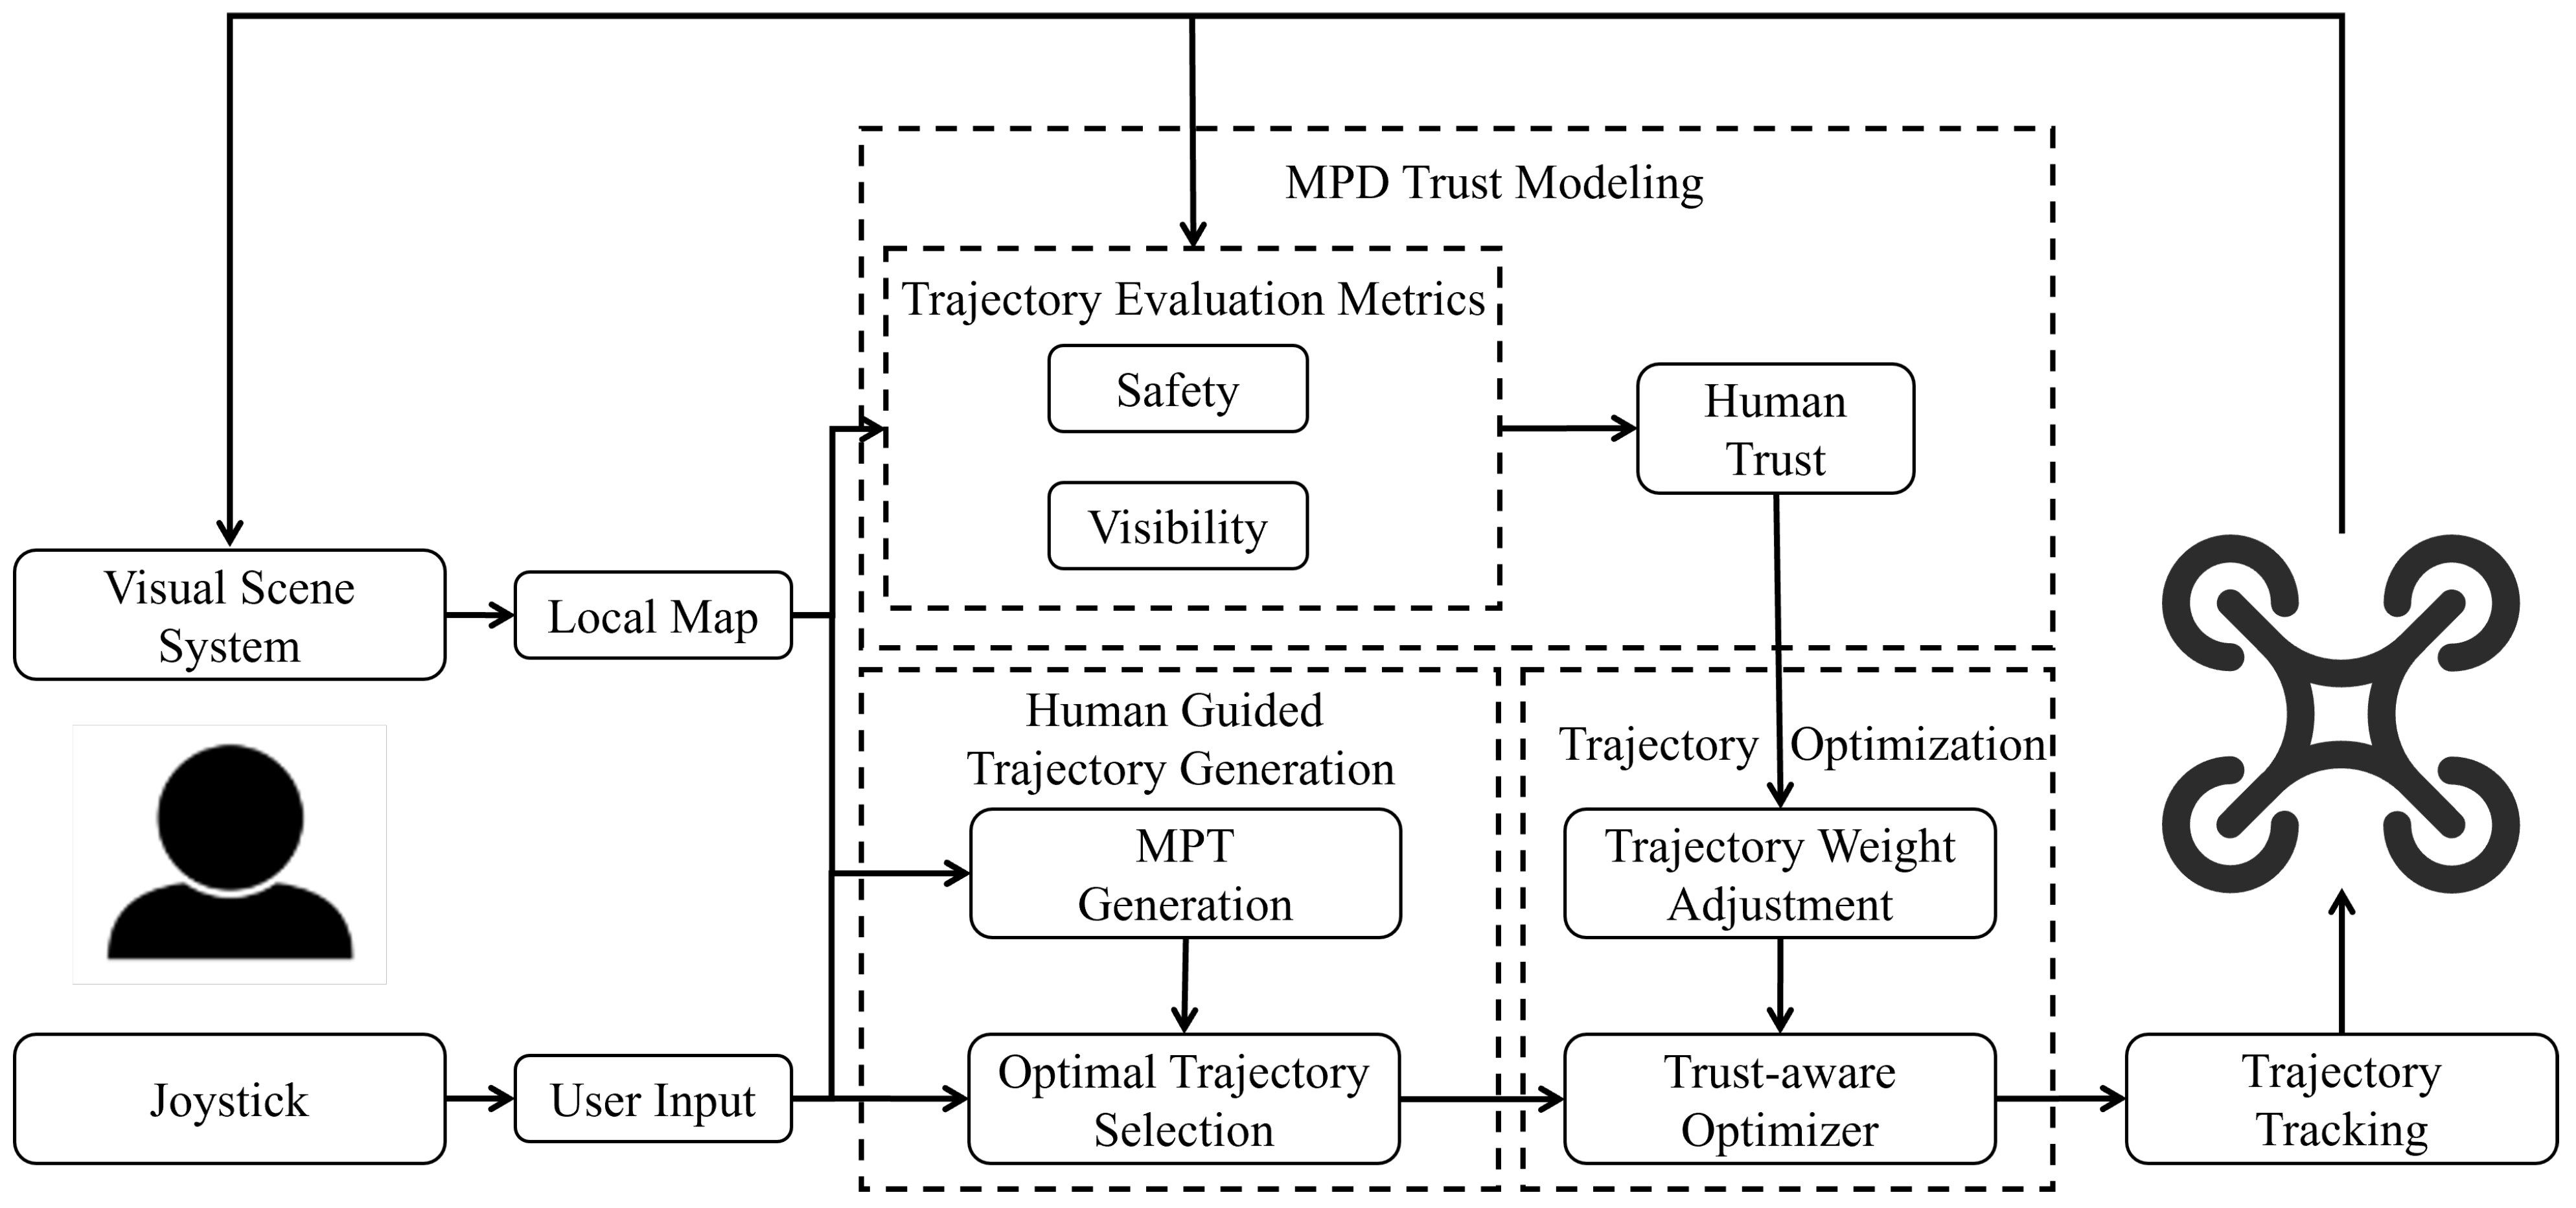
Human–machine collaboration in assistive aerial teleoperation is frequently compromised by trust imbalances, which arise from the vehicle’s complex dynamics and the operator’s constrained perceptual feedback. We introduce a novel framework that enhances collaboration by dynamically integrating a model of human trust into the unmanned aerial vehicle’s trajectory planning. We first propose a Machine-Performance-Dependent trust model, specifically tailored for aerial teleoperation, that quantifies trust based on real-time safety and visibility metrics. This model then informs a trust-aware trajectory planning algorithm, which generates smooth and adaptive trajectories that continuously align with the operator’s trust level and intent inferred from control inputs. Extensive simulations conducted in diverse forest environments validate our approach. The results demonstrate that our method achieves task efficiency comparable to that of a trust-unaware baseline while significantly reducing operator workload and improving trajectory smoothness, achieving reductions of up to 23.2% and 43.2%, respectively, in challenging dense environments. By embedding trust dynamics directly into the trajectory optimization loop, this work pioneers a more intuitive, efficient, and resilient paradigm for assistive aerial teleoperation.
Keywords: assistive aerial teleoperation; human trust; motion and path planning; human–machine systems assistive aerial teleoperation; human trust; motion and path planning; human–machine systems