Article

Comprehensive Compensation Method for Motion Trajectory Error of End-Effector of Cable-Driven Parallel Mechanism


1
School of Mechatronics Engineering, Henan University of Science and Technology, Luoyang 471003, China
2
Henan Key Laboratory for Machinery Design and Transmission System, Henan University of Science and Technology, Luoyang 471003, China
*
Author to whom correspondence should be addressed.
Machines 2023, 11(5), 520; https://doi.org/10.3390/machines11050520

Submission received: 27 March 2023 / Revised: 22 April 2023 / Accepted: 27 April 2023 / Published: 1 May 2023
(This article belongs to the Special Issue Development and Applications of Parallel Robots)

Abstract

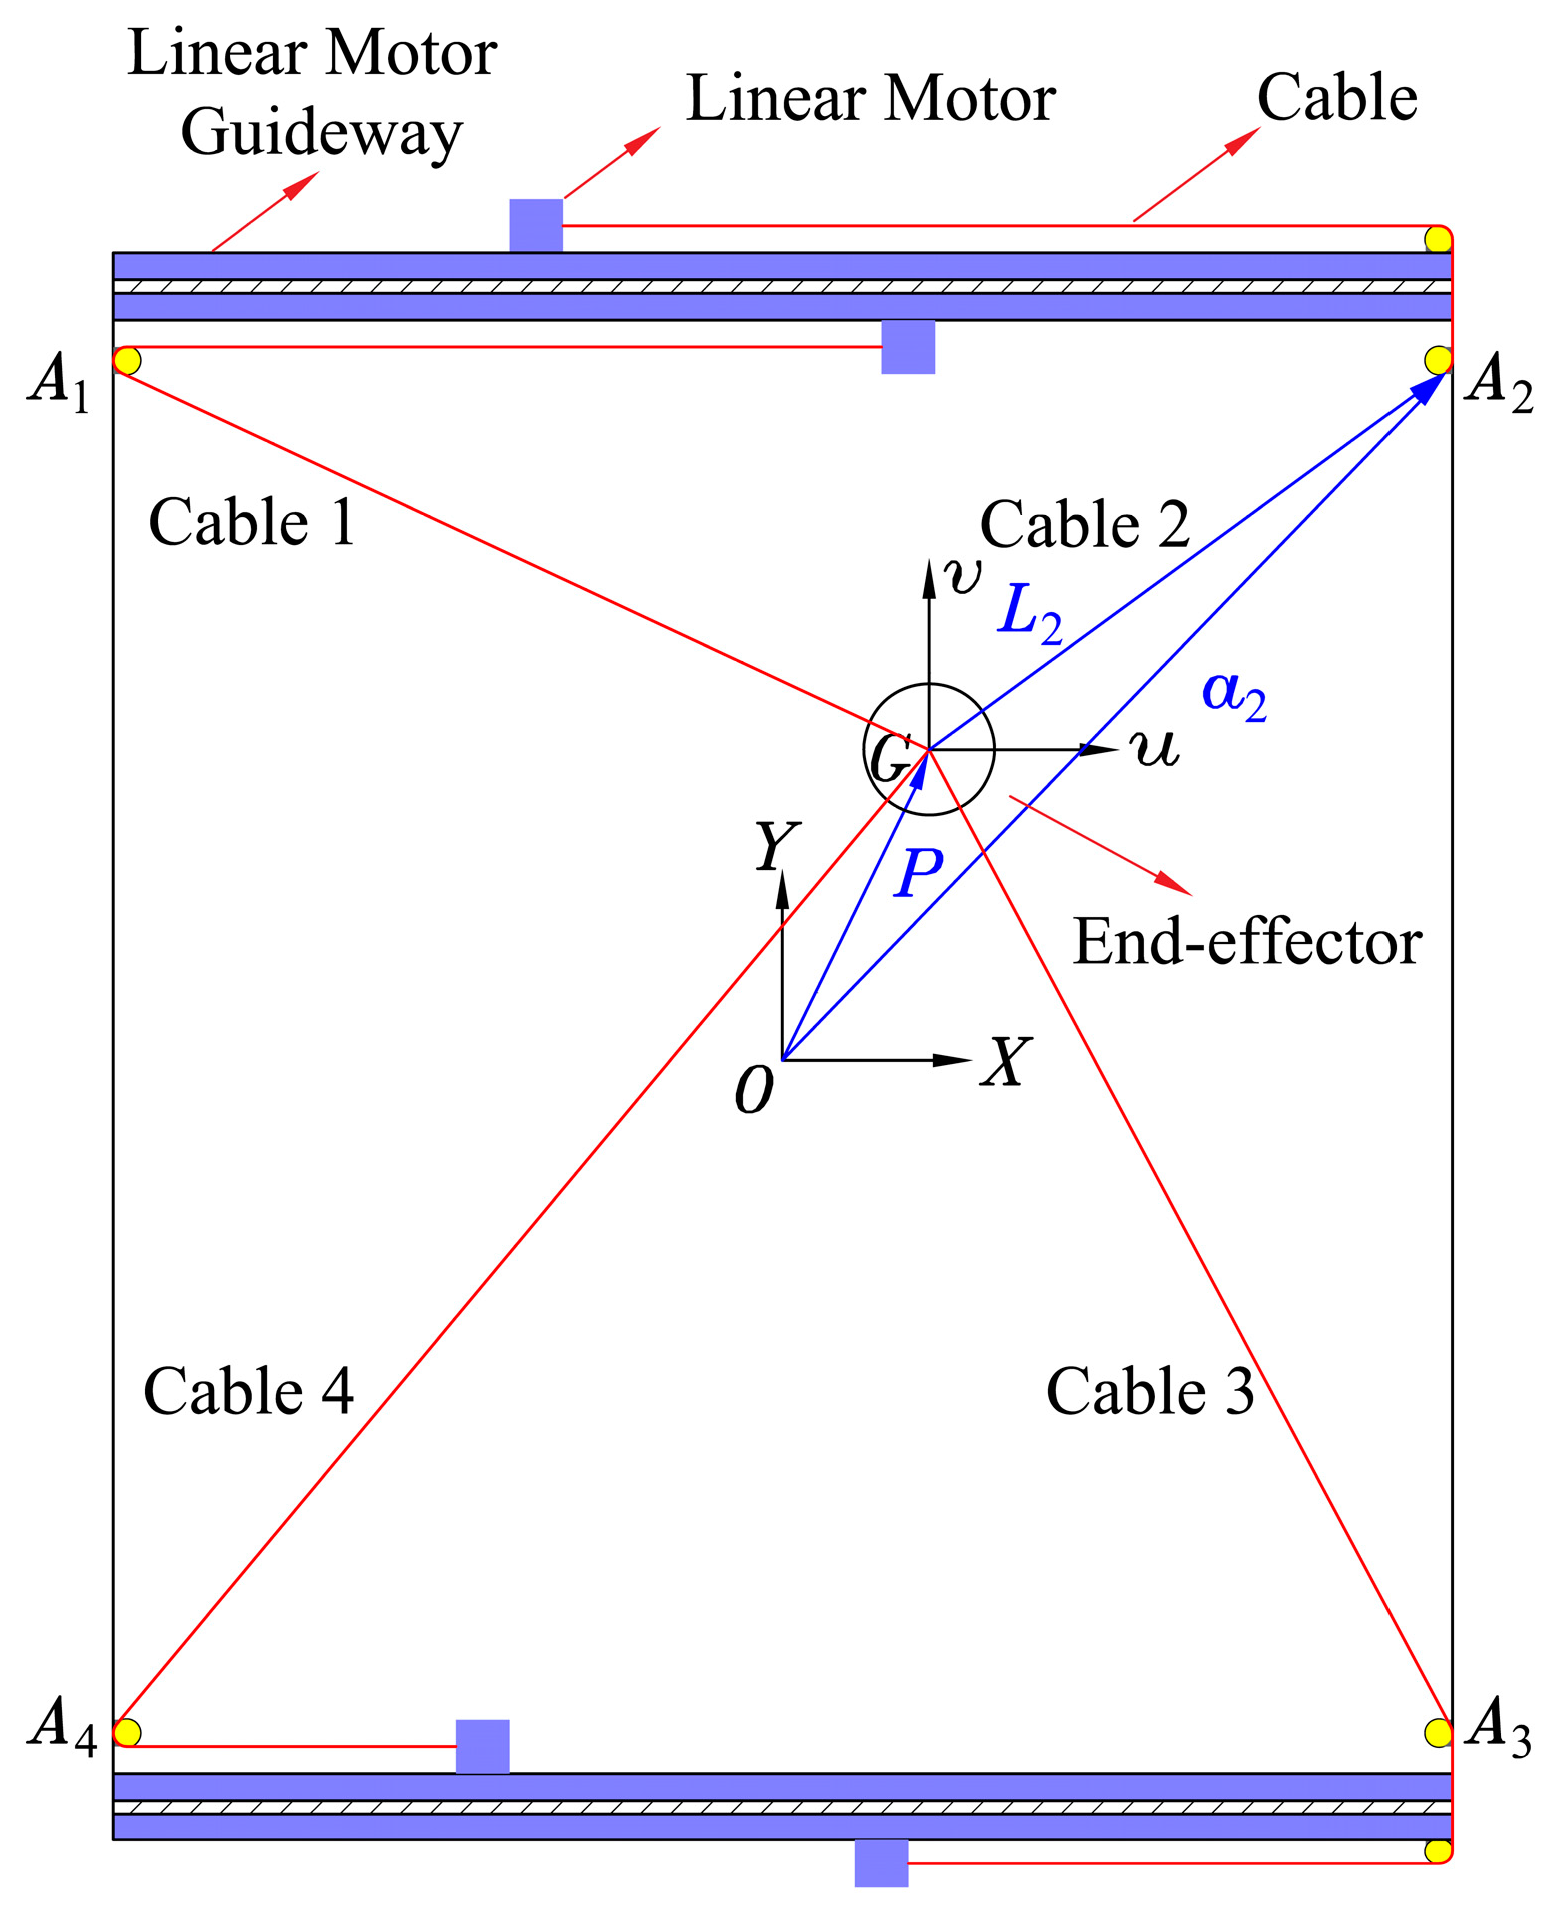
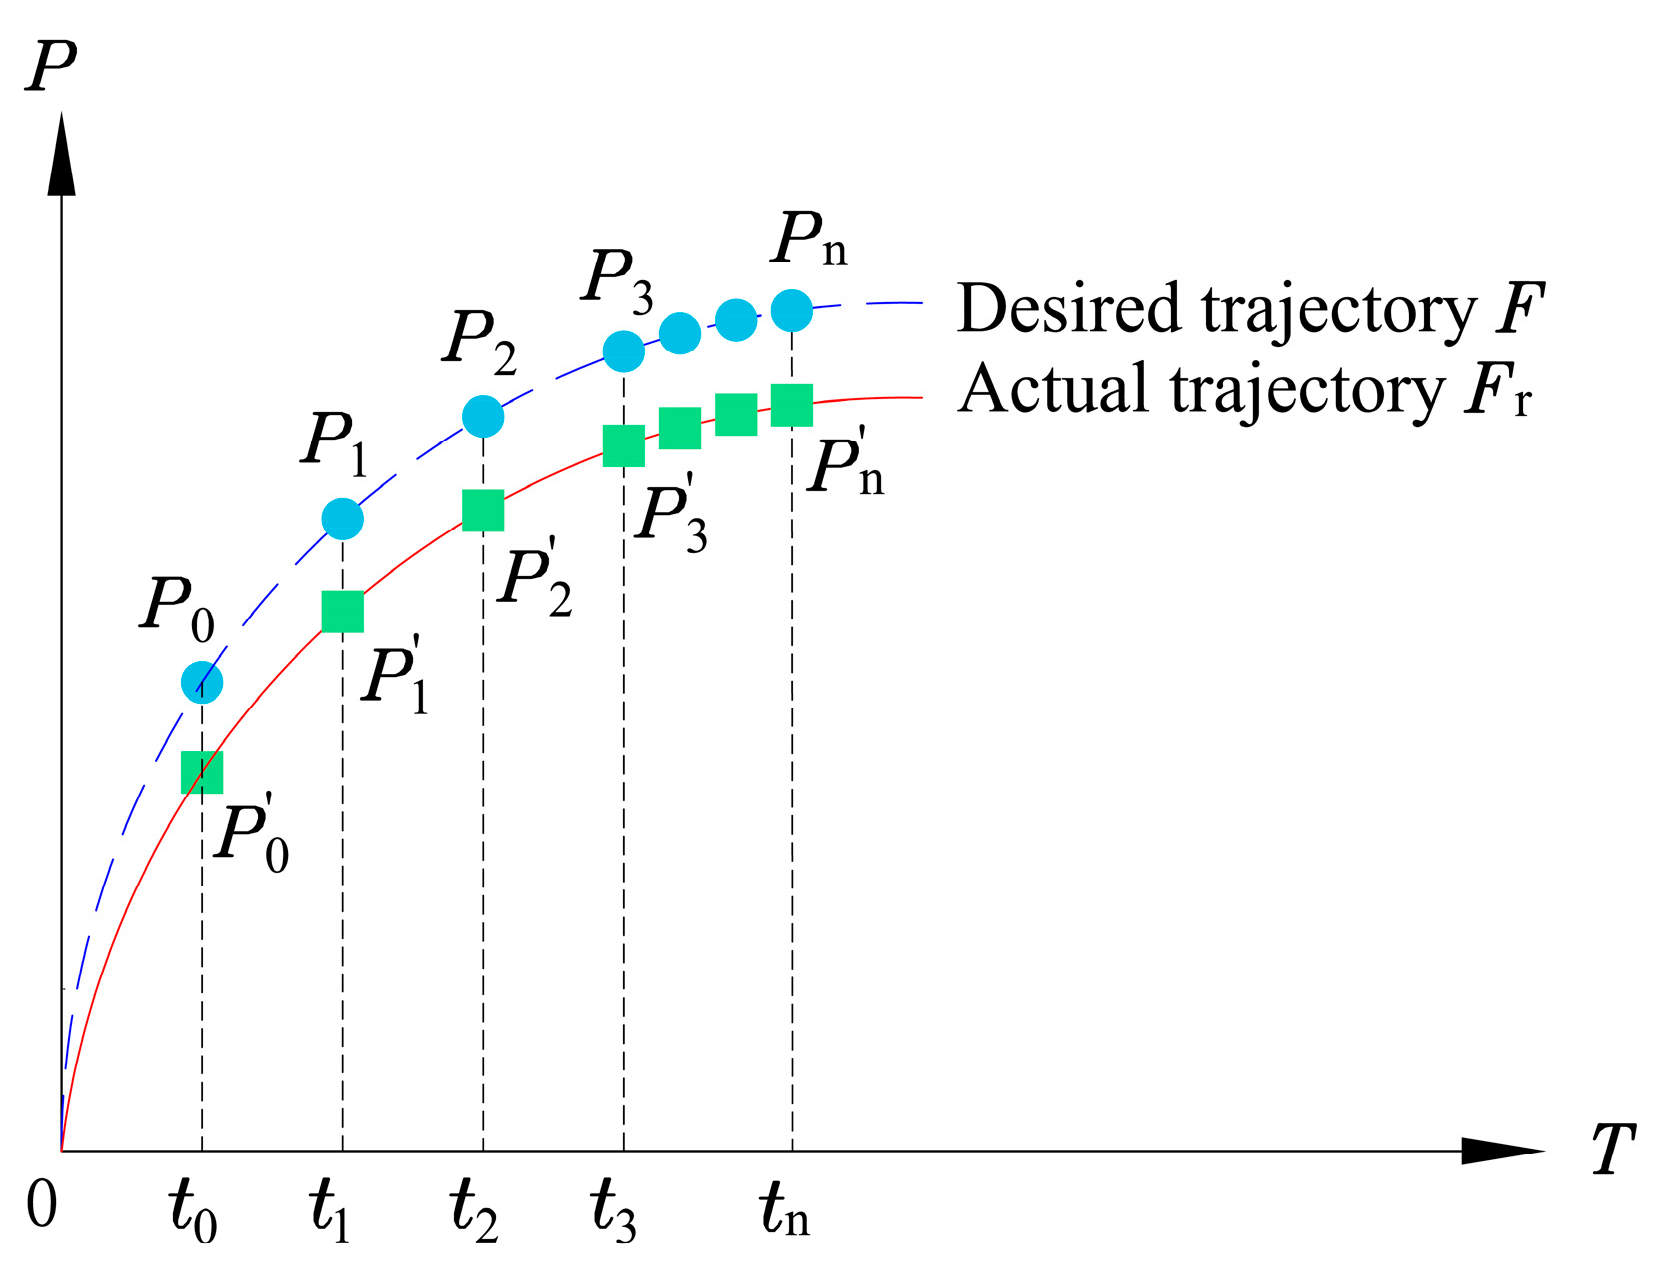
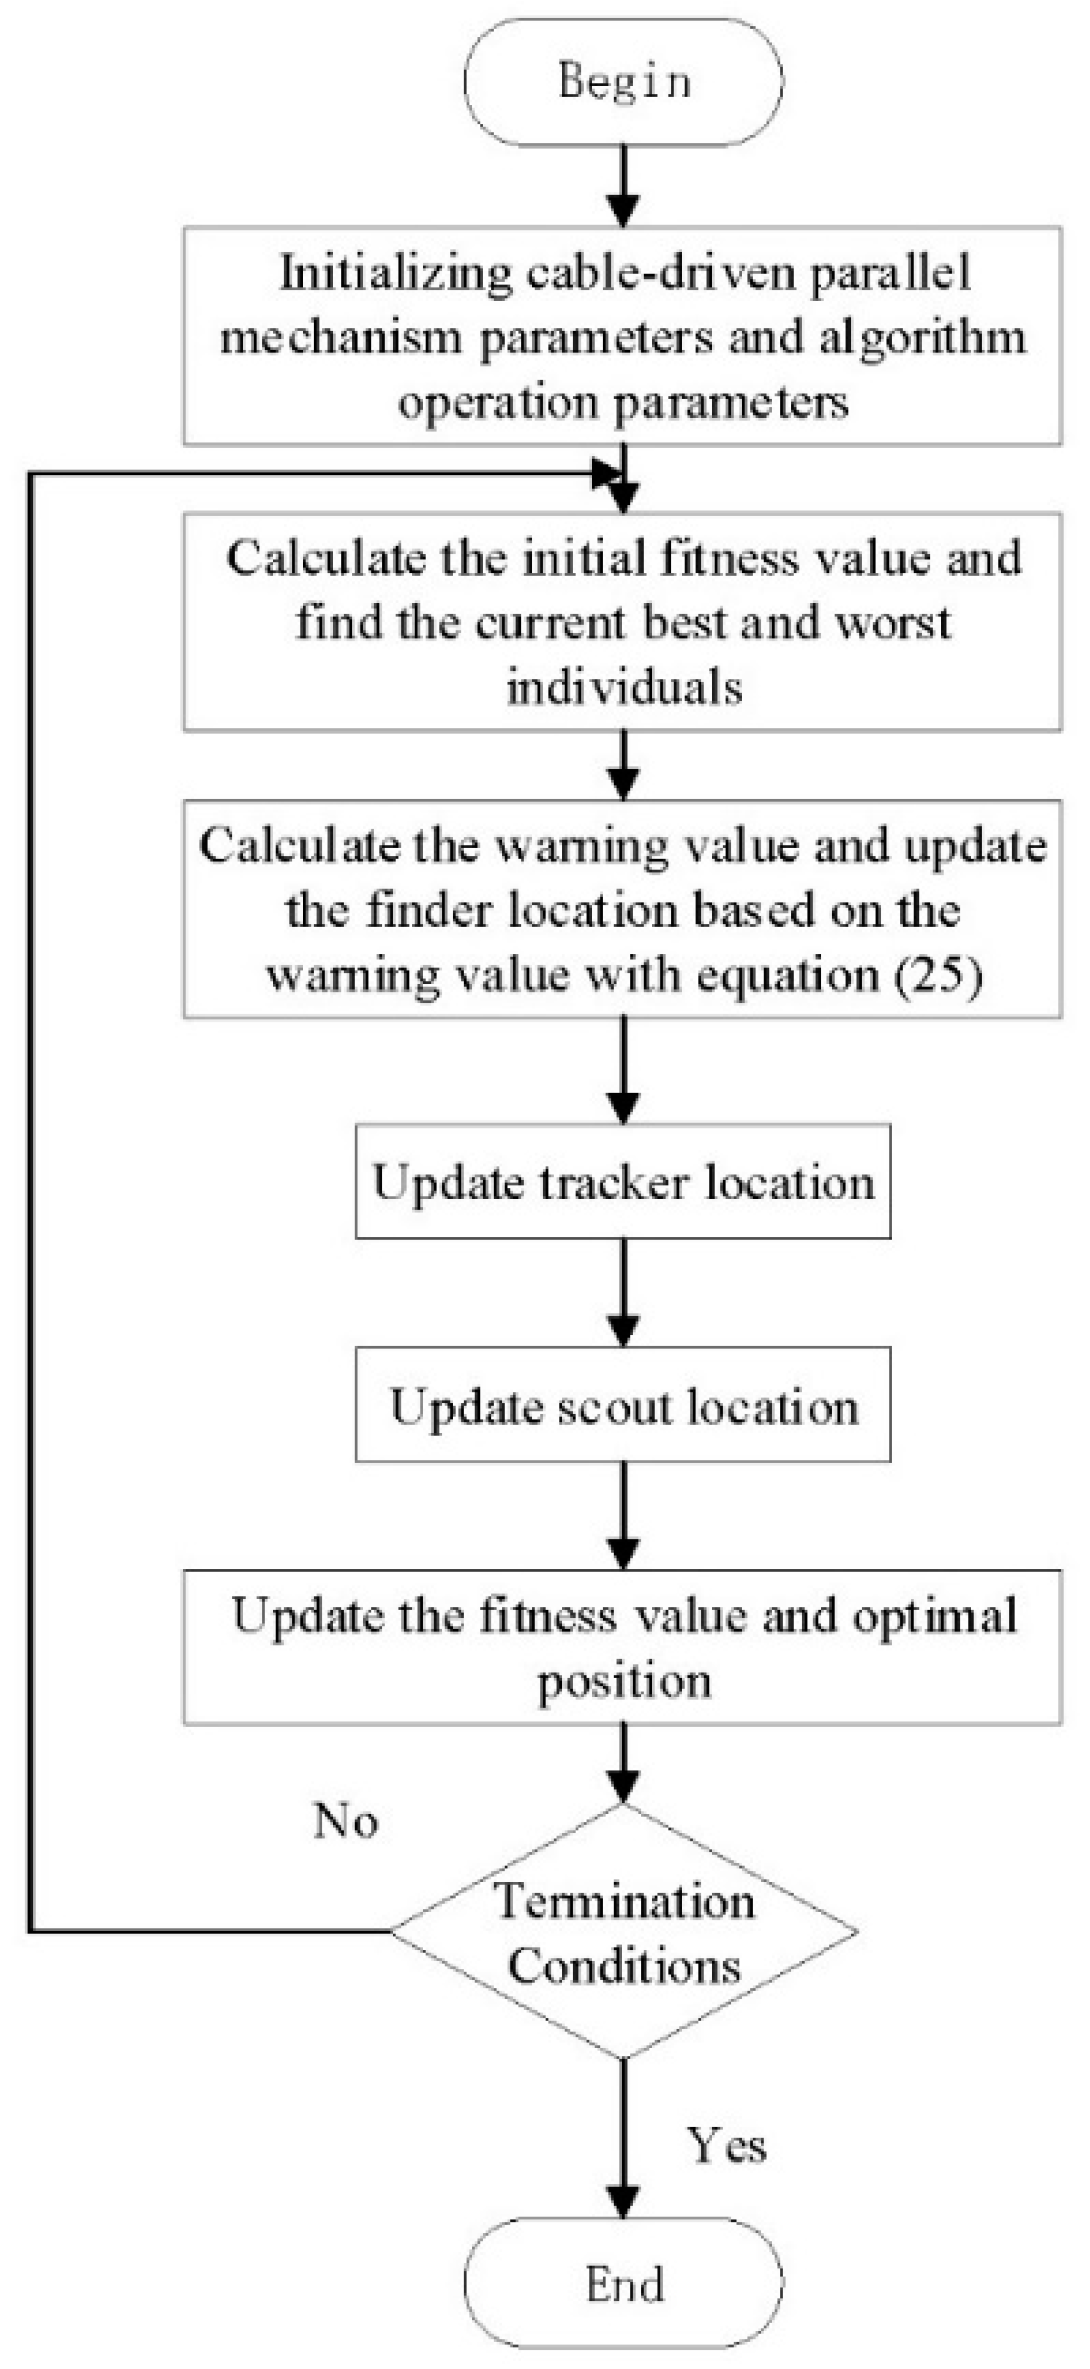
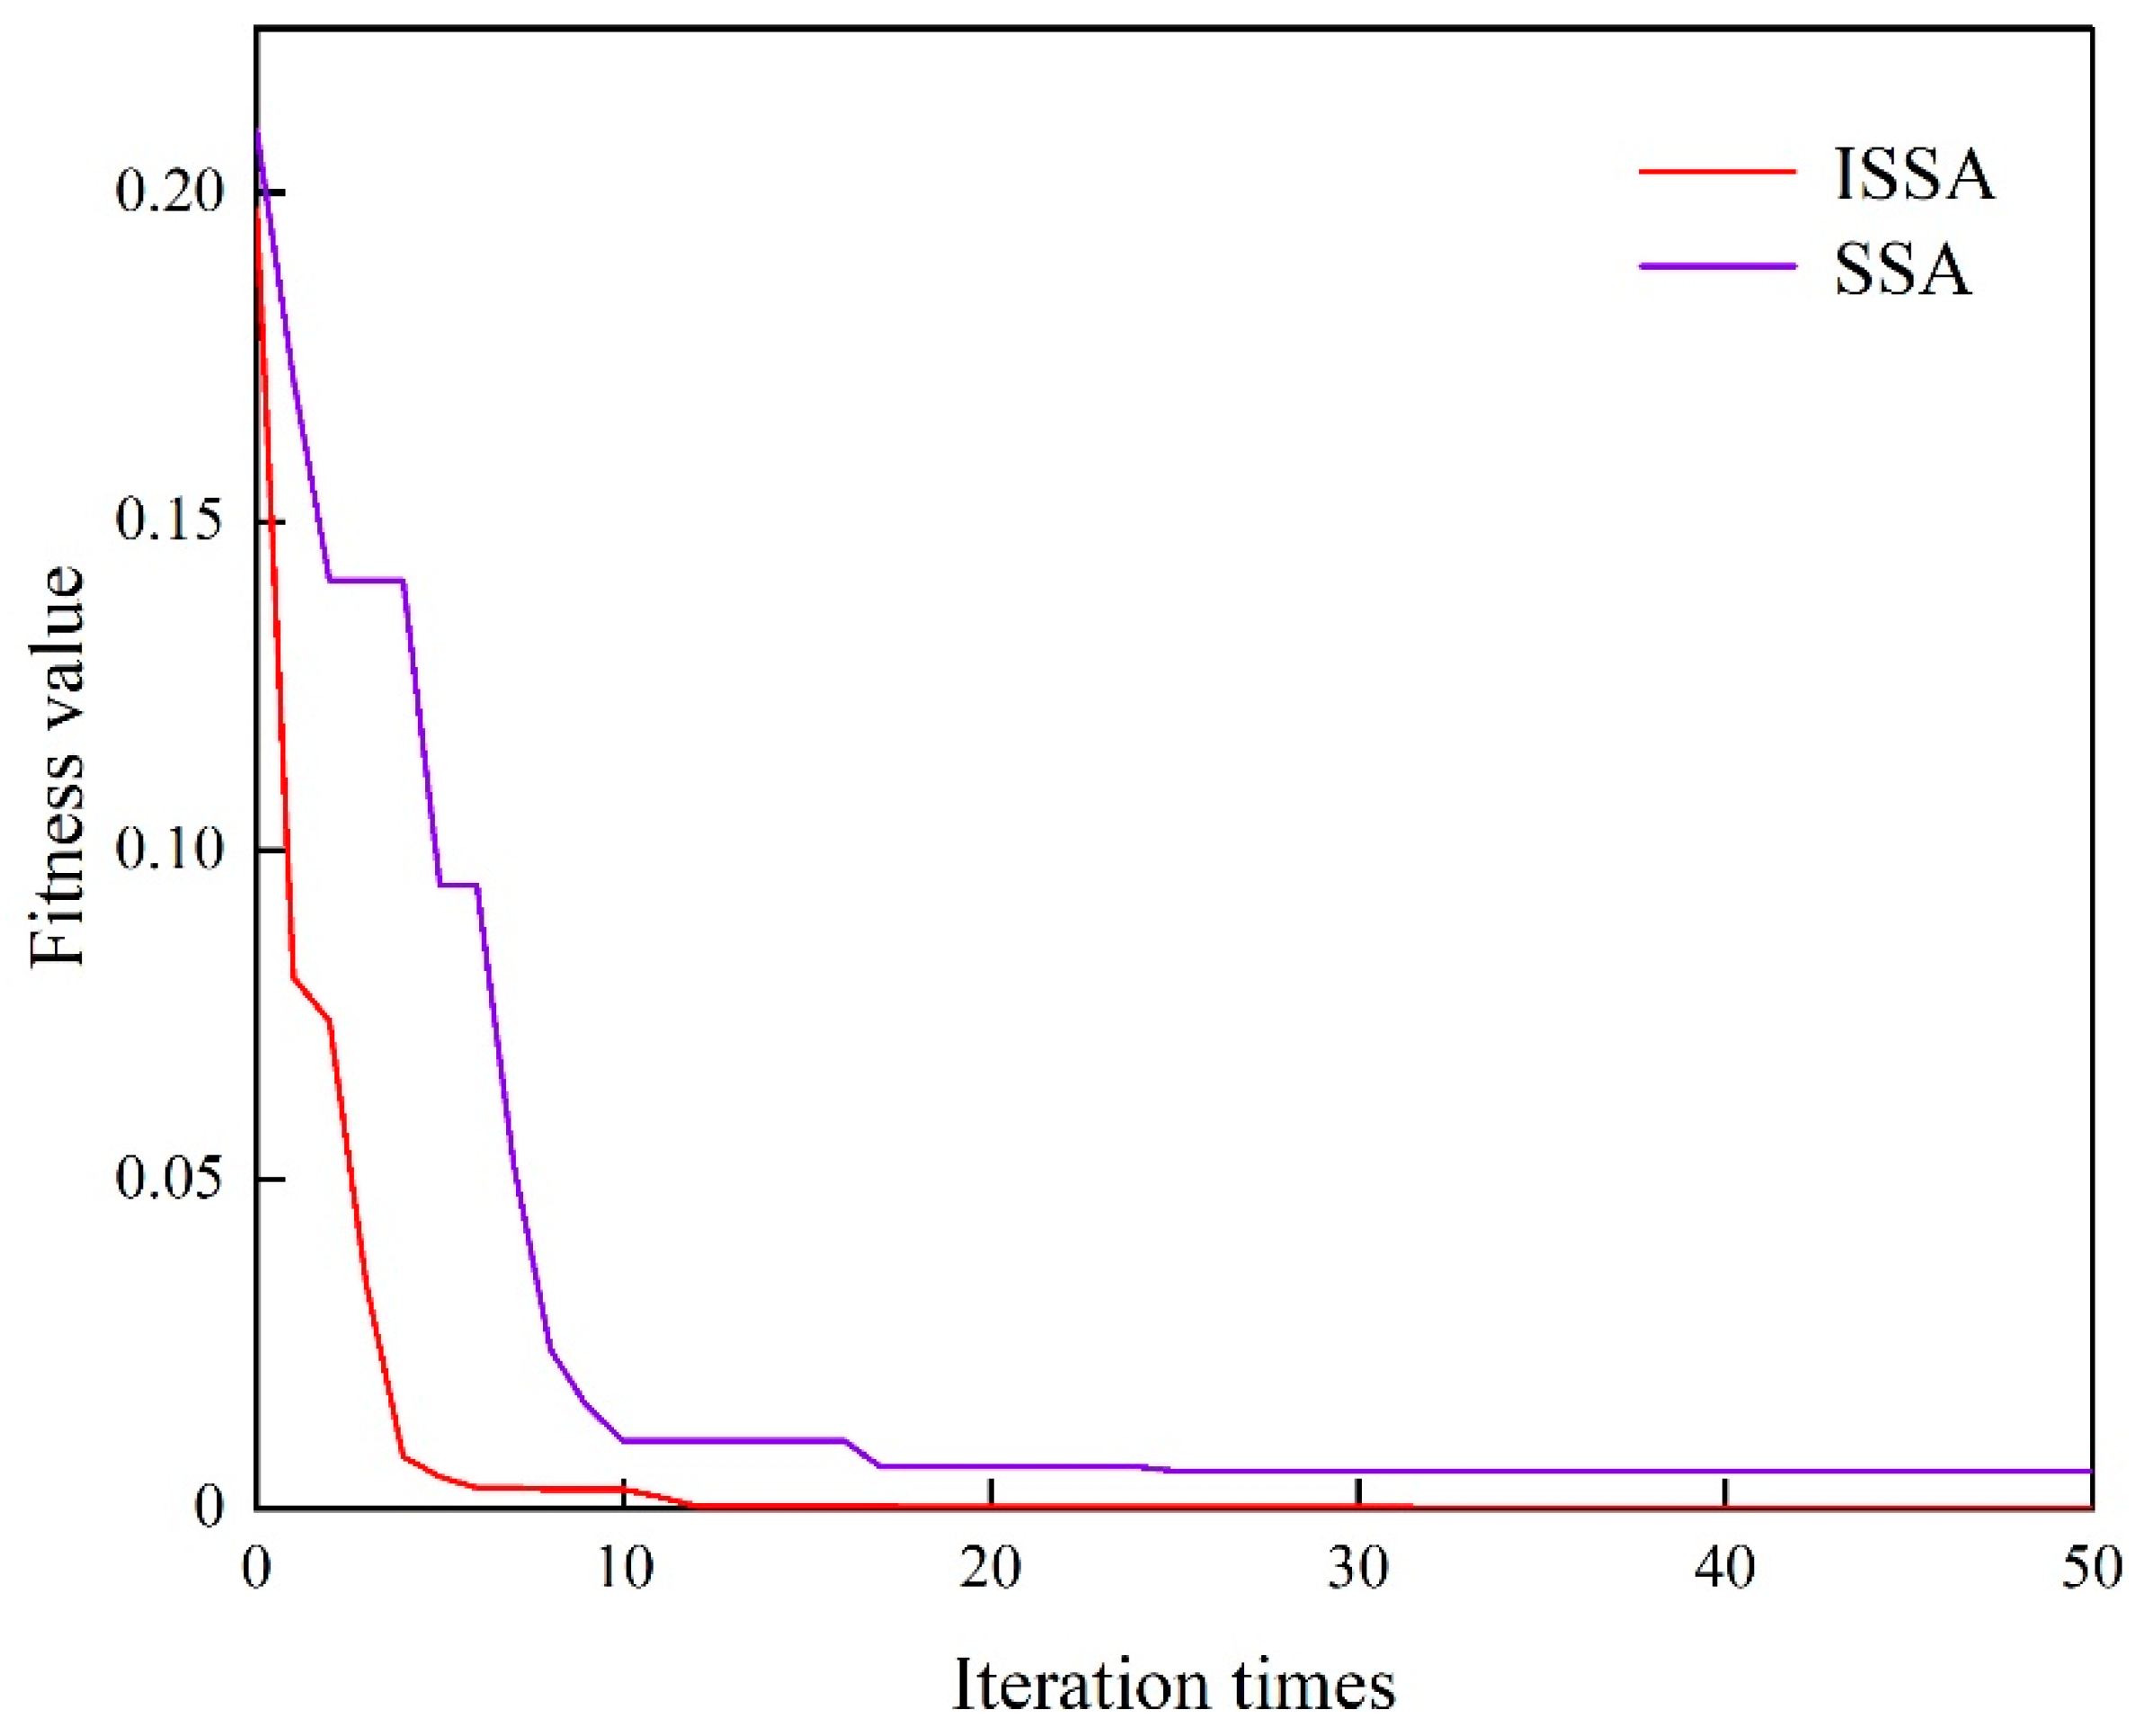
The accuracy of the end-effector motion trajectory is a critical performance indicator for cable-driven parallel mechanisms. This study aims to address the problem of trajectory error during the end-effector motion in a cable-driven parallel mechanism. It proposes a comprehensive compensation method based on the simultaneous application of the improved sparrow search algorithm and the cable length space error compensation algorithm, leveraging kinematic analysis. To compensate for the motion trajectory error of the end-effector caused by the geometric parameter error, the study establishes the kinematic model of the cable-driven parallel mechanism using the vector method. It creates the end-effector position error model and motion trajectory error model using the differential kinematic theory, analyzes the impact of the geometric parameter error on the motion trajectory error, constructs the kinematic parameter identification matrix, and uses an improved sparrow search algorithm to compensate for the position error of the motion trajectory interpolation point. For the motion trajectory error of the end-effector caused by non-geometric parameter error, the study analyzes the intrinsic correlation between the adjacent position error of the end-effector and the variation of the cable length using the error similarity theory. It then compensates for the position error of the interpolation point of the trajectory using a cable length space interpolation compensation method to enhance the motion trajectory accuracy of the end-effector. The study experimentally verifies the proposed comprehensive compensation method for end-effector motion trajectory error on a 4-cable-driven 2-DOF parallel mechanism, which reduces the motion trajectory error of the end-effector by 75%.
Keywords: cable-driven parallel mechanism; motion trajectory error compensation; parameter identification; improved sparrow search algorithm cable-driven parallel mechanism; motion trajectory error compensation; parameter identification; improved sparrow search algorithm