Article

Numerical Simulation of Mineral Separation Method Using an Isodynamic Magnetic Field

Zhengzhou Institute of Multipurpose Utilization of Mineral Resources, Chinese Academy of Geological Sciences, Zhengzhou 450006, China
*
Author to whom correspondence should be addressed.
Minerals 2026, 16(7), 761; https://doi.org/10.3390/min16070761
Submission received: 1 June 2026 / Revised: 13 July 2026 / Accepted: 18 July 2026 / Published: 22 July 2026
(This article belongs to the Section Mineral Processing and Extractive Metallurgy)

Abstract

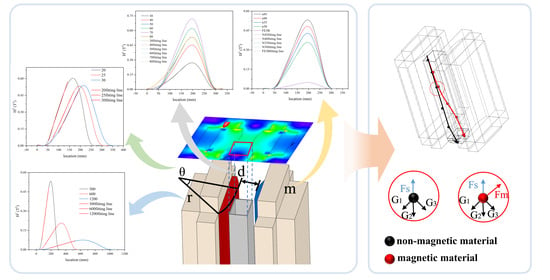
An improved method for separating magnetic minerals based on an isodynamic magnetic field is proposed in this work. The magnetic field distribution generated by the system was first analyzed through numerical simulations performed with finite element electromagnetic simulation software, and the simulation accuracy was subsequently validated against experimental data. Through system modeling and parameter sensitivity analysis, the regulatory mechanisms of various parameters of the field properties were thoroughly investigated. Numerical results show that a constant magnetic force field forms in the separation zone at a 25° arc center angle of the curved pole head, while poor field uniformity occurs at 20° or 30°. A stable constant magnetic force field can be generated in the separation zone when the large arc radius of the curved pole head is 300 mm, 600 mm or 1200 mm, or when permanent magnet materials including N30–N45-grade neodymium iron boron (NdFeB) and ferrite are adopted. The large arc radius of the curved pole head, as well as the type and grade of the permanent magnet, only affect the magnitude of the magnetic force in the separation zone, with no significant correlation with the uniformity of the constant magnetic force field. A constant magnetic force field is generated when the thickness of the side patch magnet on the curved pole head is 40–70 mm and the magnetic system working air gap is 50–60 mm; the magnetic force field will lose uniformity once the parameters deviate from the above ranges.

Graphical Abstract

1. Introduction

With the progressive depletion of global mineral resources and the continuous tightening of environmental protection policies, the market demand for high-grade iron ore has shown a sustained and significant upward trend [1,2]. As a core beneficiation technology, magnetic separation has prominent inherent advantages including low environmental footprint and high operational reliability under both extreme and ambient conditions [3], which endows it with greater competitiveness compared to traditional mineral separation methods across diverse industrial scenarios.
The mainstream magnetic systems employed in magnetic separators can be classified into three categories: open, semi-closed, and closed magnetic systems. The structural configuration of the magnetic system directly determines the separation mode and the performance ceiling of the equipment. Conventional open and semi-closed magnetic systems exhibit magnetic field gradients directed toward the magnetic system itself, which confines them to an attraction-based separation mode susceptible to the entrainment of non-magnetic minerals during the separation process [4]. Even when the magnetic field strength and gradient are enhanced through upgrades in magnetic source materials and optimization of the magnetic system layout, the entrainment issue remains irresolvable at the structural level, thereby impeding the high-quality recovery of magnetic minerals [5]. In contrast, symmetric closed magnetic systems offer distinct structural advantages: through the symmetrical arrangement of permanent magnets and the closed-loop connection of magnetic conductors, they generate a uniformly varying magnetic field whose gradient direction is not oriented toward the magnetic system within the separation zone, thus circumventing the inherent limitations of conventional magnetic systems [6]. Building upon symmetric closed magnetic systems, the isodynamic magnetic field system further establishes a separation region characterized by constant magnetic force, achieved through a specially designed pole-head structure and optimized matching of magnetic materials. This approach transcends the technical constraints of traditional magnetic separation methods at the level of separation principles [7].
Research on the isodynamic separation principle dates back several decades: as early as the 1950s, the Frantz isodynamic separator was developed to achieve precise classification of magnetic minerals by utilizing isodynamic field characteristics, which is widely recognized as a classic landmark device in this field [8]. Since the beginning of the 21st century, Tuisku has proposed a superconducting isodynamic open-gradient magnetic separator as an improved configuration of conventional isodynamic separators, which further extends the upper limit of magnetic field strength for such precision separation devices [9]. Comprehensive existing research results indicate that the magnetic field characteristics and separation performance of magnetic separators are synergistically governed by multiple interdependent factors, namely the intrinsic properties of magnetic materials, the geometric parameters of the magnetic system, and the working air gap width. Accordingly, the refined structural design of isodynamic magnetic systems can be realized through the optimization of these magnetic system parameters [10].
With the rapid advancement of computational numerical technology in recent years, numerical simulation has been extensively adopted in the investigation of separation-related magnetic field characteristics [11,12]. Specifically, Li et al. and Zheng et al. both employed finite element analysis software to systematically study the magnetic field distribution around magnetic matrices under a superconducting magnetic field [13,14]. Among them, Li et al. explored the separation performance and magnetic field properties of a novel matrix structure, while Zheng et al. completed the numerical simulation and experimental validation of the magnetic field for a special-shaped cross-section matrix applied in high-gradient magnetic separation. Furthermore, Hafner et al. and Baik et al. also investigated the magnetic induction characteristics of novel magnetic separation matrices with three-dimensional structural features via magnetic field numerical simulation. Hafner et al. established a calculation and visualization method for three-dimensional magnetic flux lines, and Baik et al. conducted a systematic analysis of the magnetic field distribution and gradient characteristics around the matrix for high-gradient magnetic separation (HGMS) [15,16]. Despite the remarkable breakthroughs achieved in current research on magnetic field numerical simulation, the methodology and system for verifying the reliability of numerical calculation results still need to be further refined [17,18].
Building on prior research on isodynamic separation, this work proposes an isodynamic magnetic system featuring a static Halbach array configuration free of moving components and a magnetic separation matrix. We systematically optimize the key structural parameters of the magnetic system via finite element numerical simulation, and quantitatively reveal the influence pattern of each parameter on the uniformity of the isodynamic magnetic field. This study aims to establish a reliable numerical calculation approach, provide structural optimization references for improving the separation performance of such devices, and advance further research on isodynamic separation.

2. Separation Principle and Magnetic Field Computation

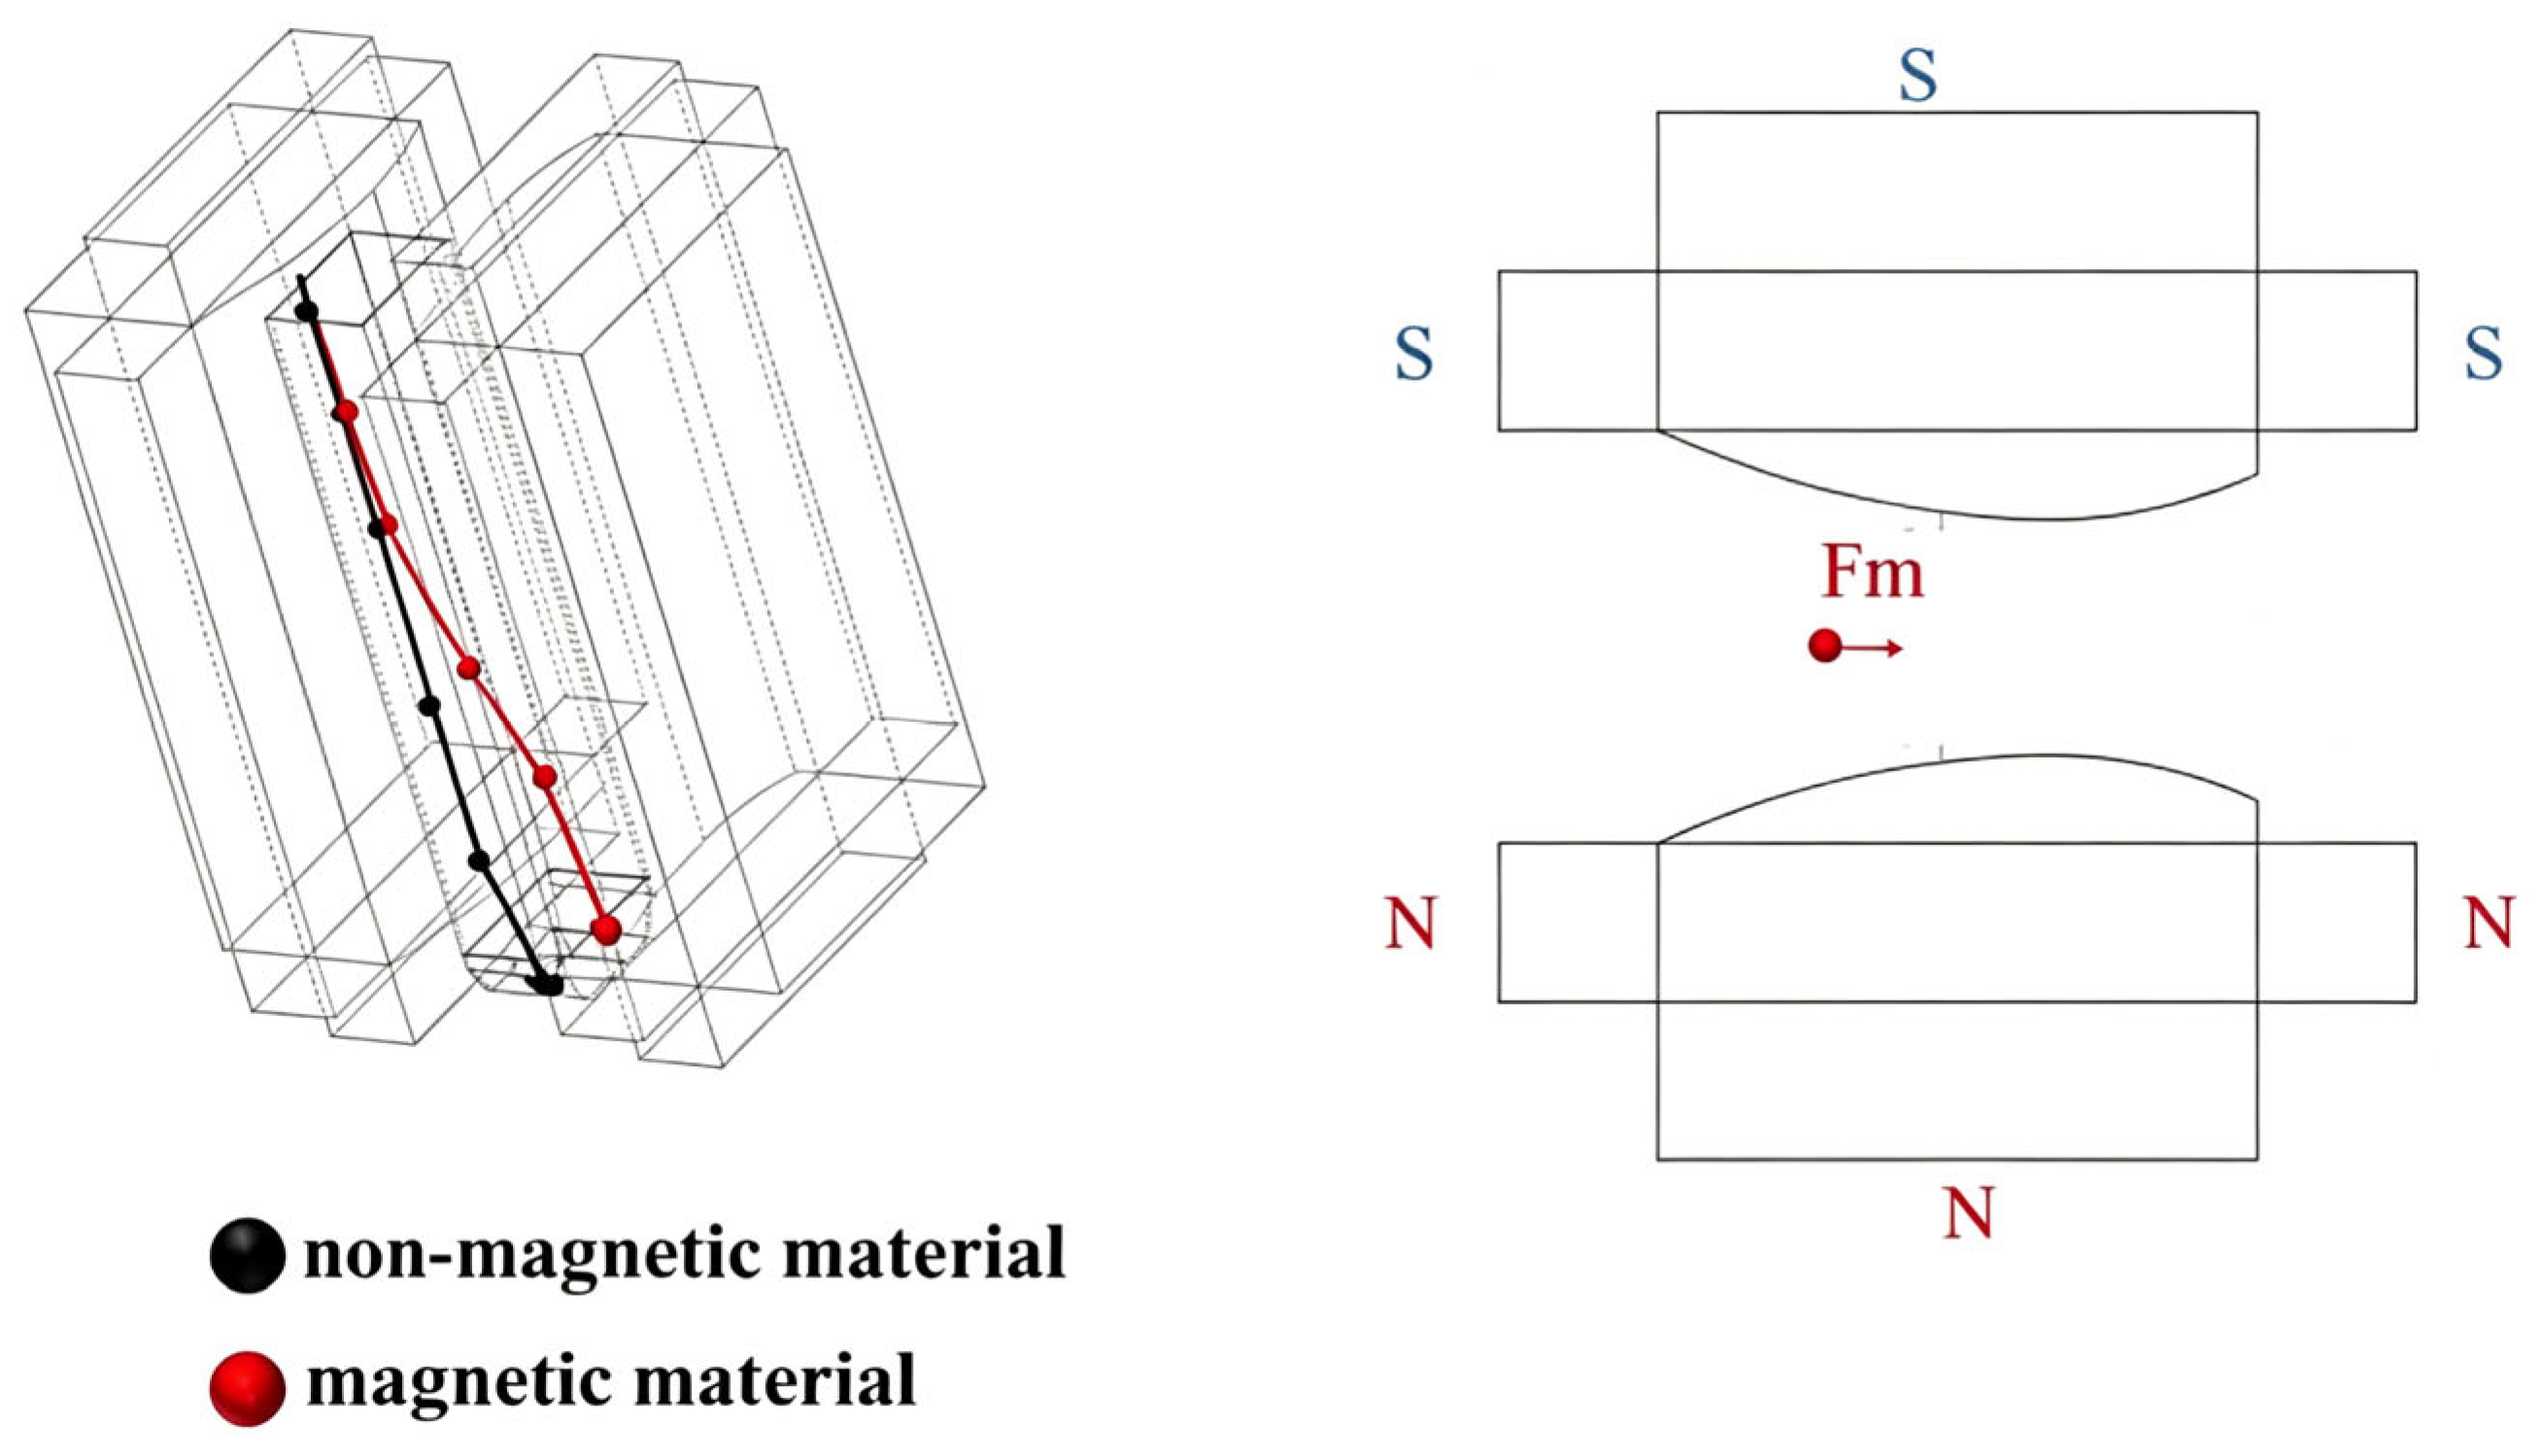
The structure of the isodynamic magnetic system with a static Halbach array configuration proposed in this study is shown in Figure 1. The left subfigure depicts the overall configuration of the magnetic circuit, while the right subfigure provides a detailed cross-sectional view of the separation zone. In the right subfigure, the upper and lower magnetic poles are designated as the N-pole and S-pole, respectively. The working magnetic flux is generated by permanent magnet patches arranged around the curved pole heads. Owing to the geometric profile of the curved pole heads, the magnetic flux density in the inter-pole gap increases gradually as the gap narrows, leading to a corresponding increase in magnetic field strength along the central axis. Consequently, a non-uniform background magnetic field is established within the separation zone. By carefully optimizing the contour of the pole heads, an isodynamic magnetic field that satisfies the requirements for efficient mineral separation can be produced in the separation space. The proposed isodynamic magnetic separator has a well-defined and targeted application scope. It is particularly suitable for separating weakly magnetic paramagnetic minerals based on subtle differences in magnetic susceptibility, such as wolframite, ilmenite, monazite, and scheelite. Optimal processing conditions require fully liberated ores with a dry, narrow particle size fraction of 0.074–0.25 mm, under which the uniform isodynamic magnetic field enables precise separations that are difficult to achieve with conventional magnetic separators.
The motion of magnetic particles in the magnetic separation field is governed by the combined action of multiple forces. According to Newton’s second law, the governing equation for particle motion can be expressed as:
m d dt V = F m + F g + F s
In magnetic separation systems, the primary forces acting on magnetic particles are the magnetostatic force (Fm), the gravitational force (Fg), and the normal support force (Fs). These forces can be described by the following fundamental equations:
F m = V ε μ 0 H grad H
F g = V ρ g
B = μ 0 H
B = μ 0 grad H
where V denotes the particle volume, m3; ρ represents the density of the magnetic mineral particle, kg·m−3; μ0 is the magnetic permeability of air, N·A−2; ɛ is the magnetic susceptibility of the particle; H signifies the magnetic field strength, A·m−1; gradH indicates the gradient of the magnetic field strength at the particle location, A·m−2, B is the magnetic flux intensity, T; ∇B is the magnetic flux intensity gradient at the location of the ore particle, T/m.
Consider a magnetic field in which the direction of the steepest increase in magnetic field strength H is aligned with the x-axis. For a given target particle, its volume V and magnetic susceptibility χ are constant, and the vacuum permeability μ0 is a universal constant. To maintain a constant magnitude of the magnetic force Fm acting on the particle, the product HgradH must be spatially uniform throughout the entire separation zone. This necessitates:
H grad H = c
where c is a constant independent of particle position.
d d x H 2 = 2 H grad H
By combining Equations (3)–(5) and Equation (6), it is derived that under an isodynamic magnetic field force field, the B2 function along the x-axis exhibits linearity with respect to position x. To validate whether field data conforms to this linear relationship, linear regression analysis is employed. Key statistical metrics include: R2 (coefficient of determination) and Adjusted R2 (corrected for predictors). R2 quantifies the goodness-of-fit, ranging from 0 to 1. Values closer to 1 indicate superior regression performance:
R 2 = 1 y y ^ y y
where sum of Squared Residuals ( y y ^ ) quantifies unexplained variance: larger ( y y ^ ) values indicate poorer model fit, as they represent cumulative deviations between observed data and model predictions. y y is the total sum of squares, which describes the degree of dispersion of numbers in the data set.

3. Simulation

3.1. Numerical Platform and Governing Equations

The numerical analysis of the electromagnetic field involved in this study can be ultimately boiled down to solving the mathematical model of differential equations with known boundary conditions, the electromagnetic field boundary value problem (BVP) [19]. In this work, we employ the finite element analysis (FEA) method to solve the electromagnetic field governing equations based on Maxwell’s equations under the specified boundary conditions and user-defined initial conditions [20,21]:
· H = J + D t
· E = H t
· D = ρ v
· H = 0
· J = ρ t
In the governing equations: J denotes the electric current density, A·m−2; D represents the electric displacement field, C·m−1; E signifies the electric field intensity, V·m−1; ρv is the volume charge density, C·m−3.

3.2. Model Construction and Meshing

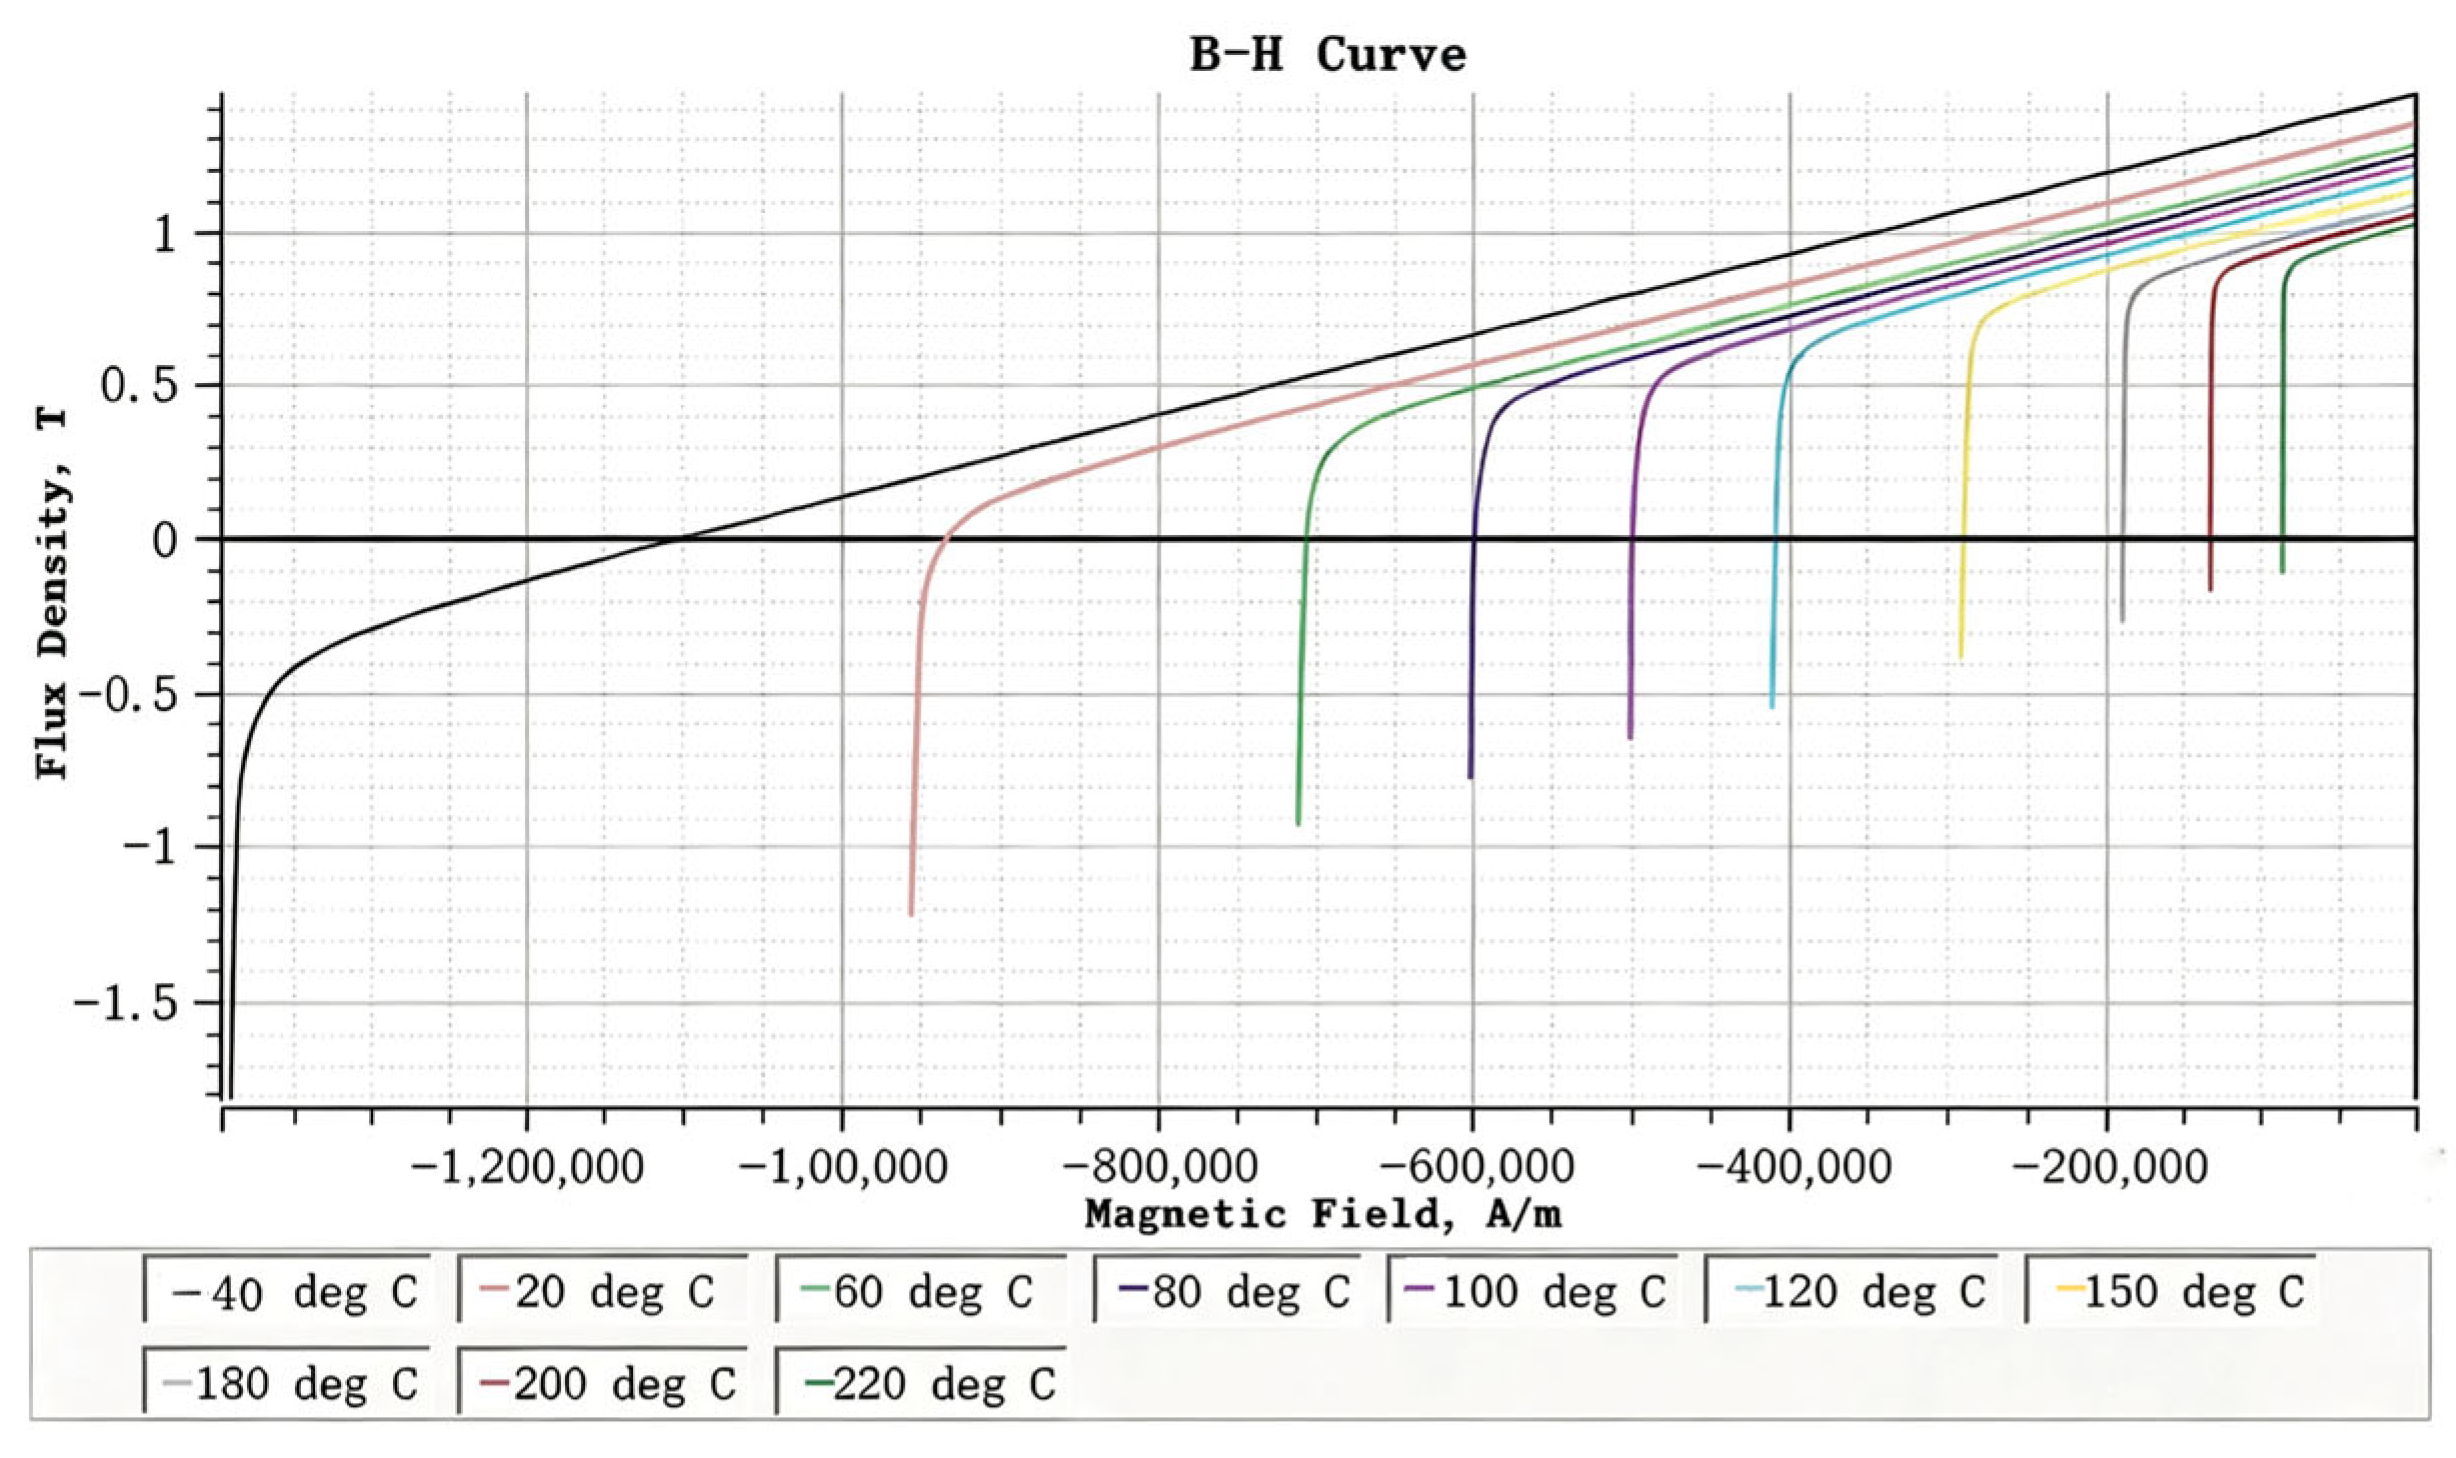
In this work, the commercial 3D modeling software CAXA 2024 was employed to construct the three-dimensional geometric model of the isodynamic magnetic system. The finite element calculation domain was defined as a rectangular air domain, which completely covers the main body of the magnetic system, the curved pole head, and the separation zone. The minimum distance between the outer boundary of the air domain and the outer edge of the magnetic system was set to more than 80 mm, to ensure sufficient attenuation of the magnetic field at the calculation domain boundary and effectively suppress the interference of the boundary effect on the magnetic field calculation accuracy in the separation zone. The material properties implemented in the numerical model are listed in Table 1, and the comprehensive physical parameters of all materials employed in this study are summarized in Table 2. Specifically, the magnetic hysteresis (BH) curve of the N45 neodymium-iron-boron (NdFeB) magnet is provided in Figure 2. The final finite element mesh of the computational domain is presented in Figure 3.
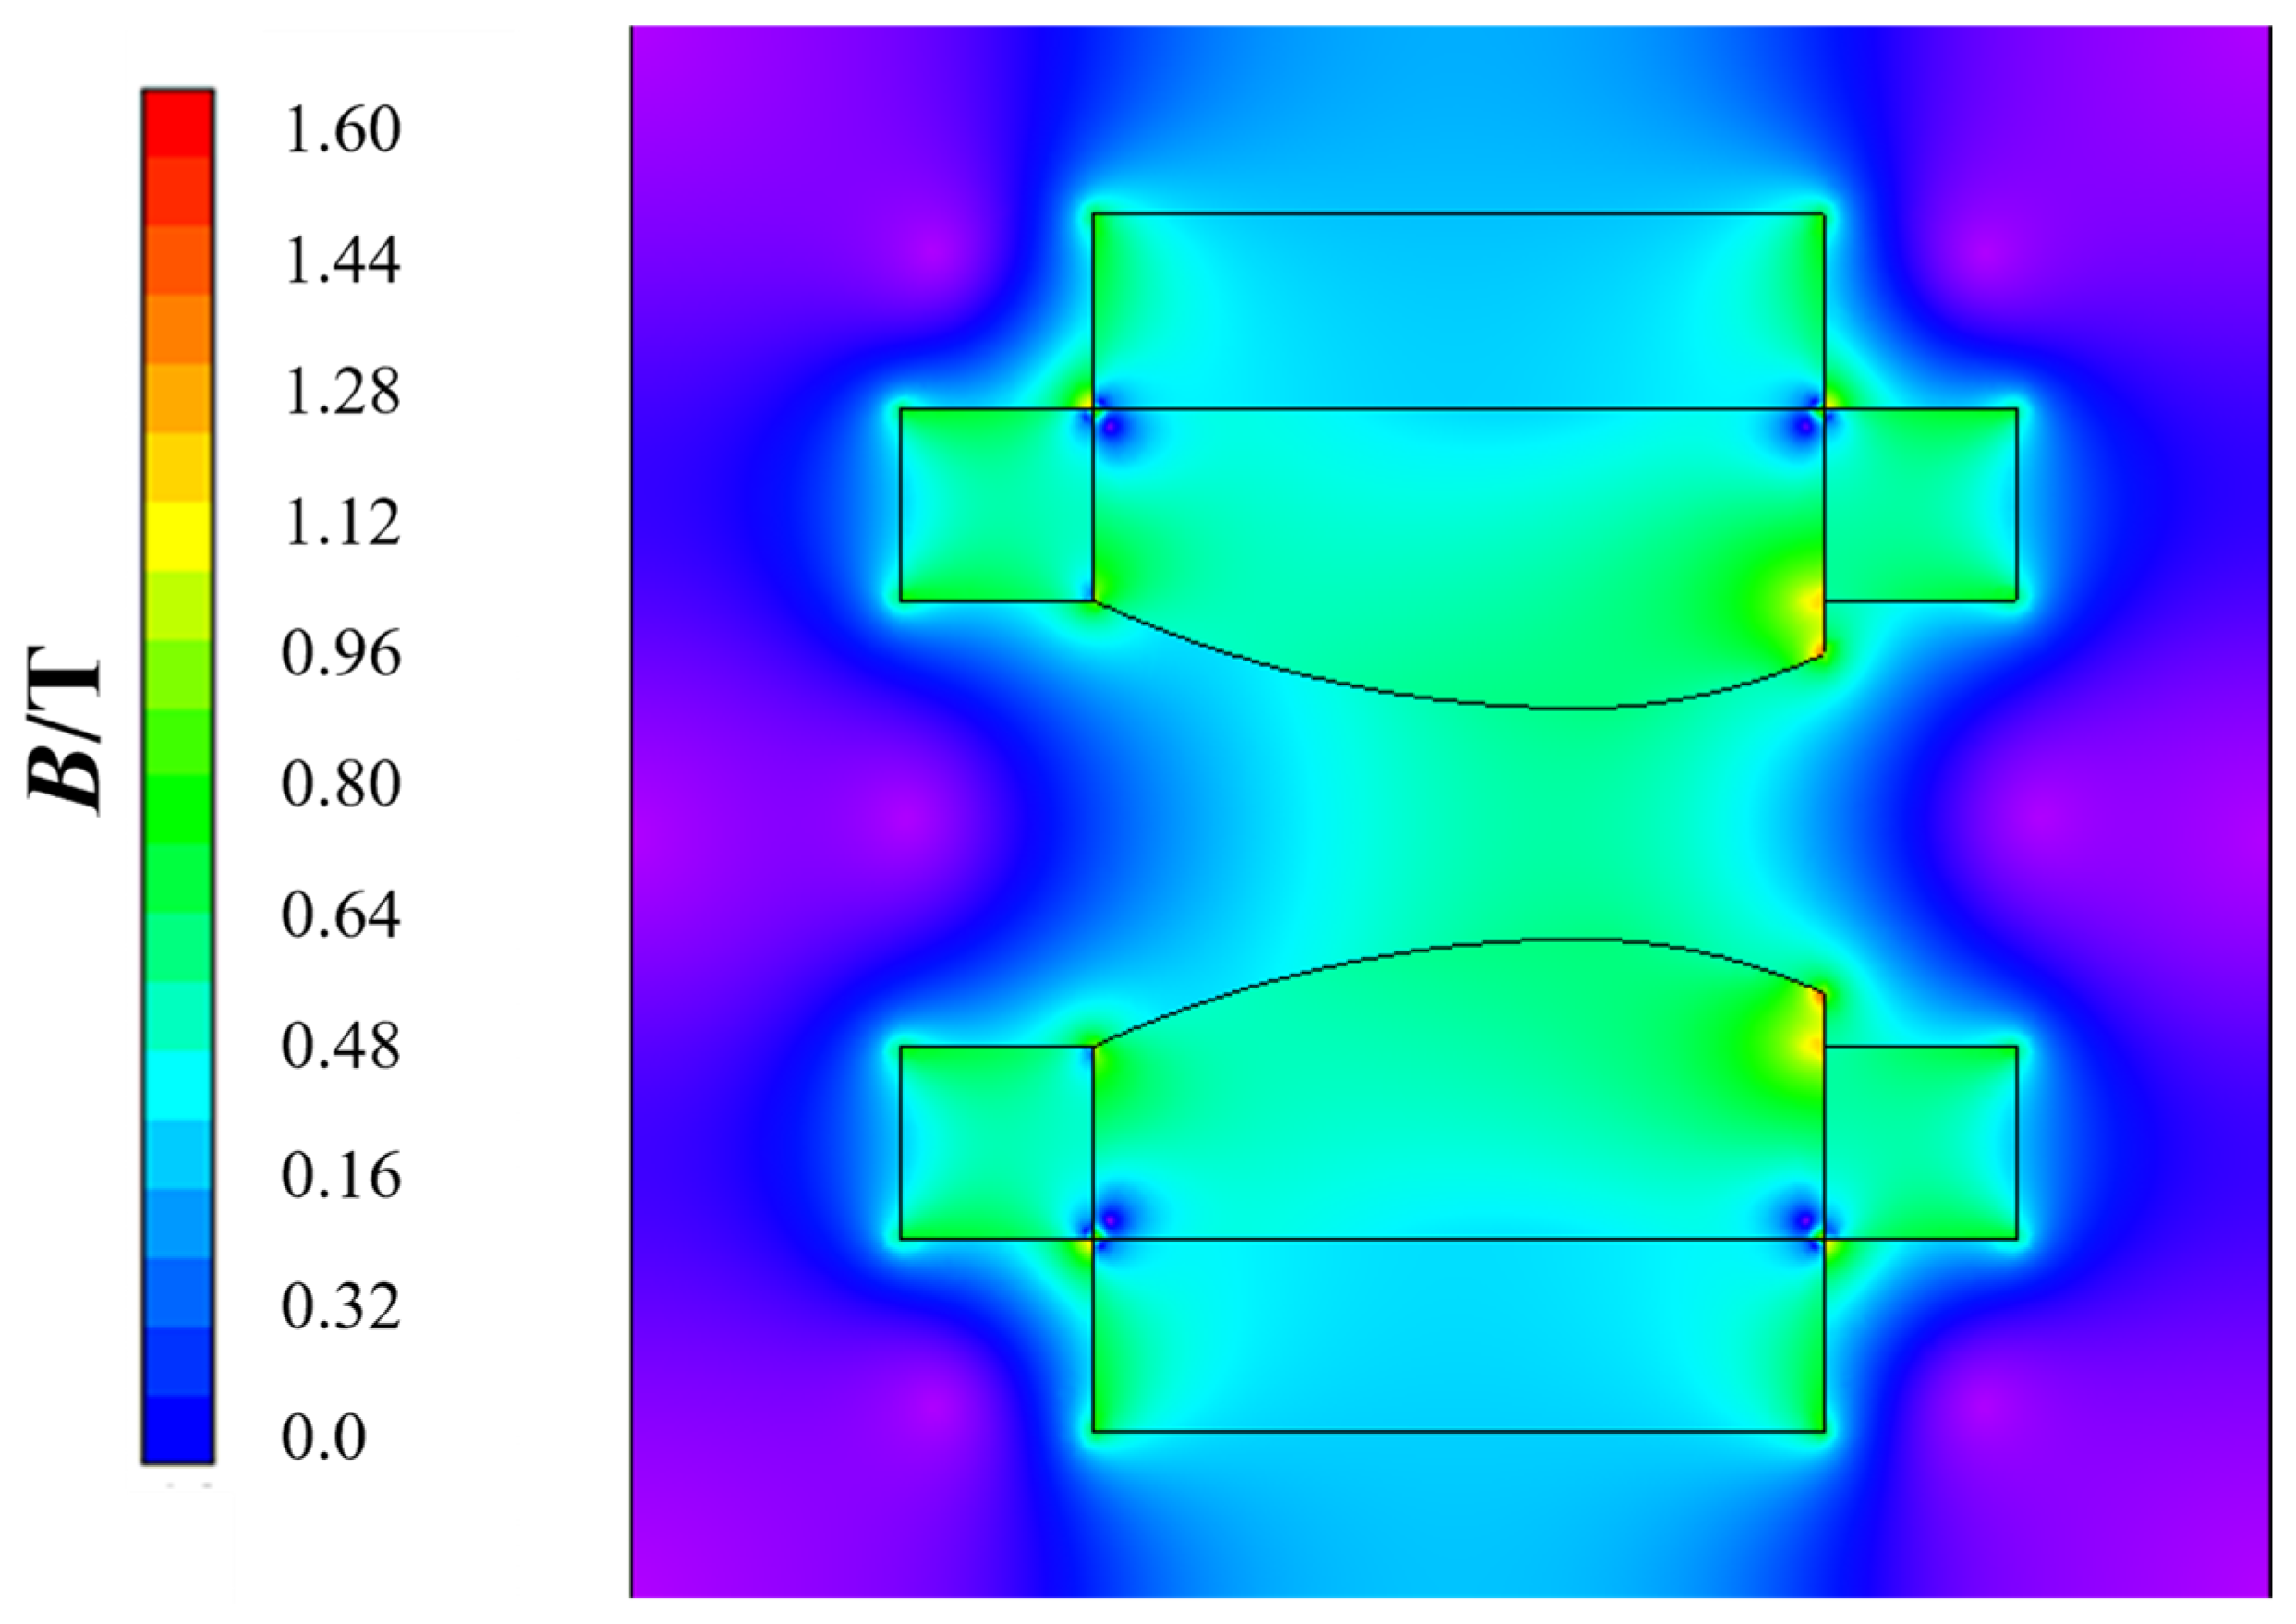
The outer boundary of the air domain was defined as a magnetic insulation boundary to eliminate the interference of magnetic flux leakage on the calculation accuracy. All interfaces between the permanent magnet and the magnetic conductive plate, as well as between the structural components of the isodynamic magnetic system and the air domain, were set as continuous boundaries to strictly guarantee the continuity of the normal component of the magnetic flux density and the tangential component of the magnetic field strength at the interfaces. In this work, a steady-state nonlinear solver was employed to perform the numerical solution of the permanent magnetic field. Dual relative convergence criteria were set as the iteration termination conditions, and the calculation was considered convergent only when both criteria were satisfied simultaneously: (1) the relative calculation error of the total magnetic energy in the solution domain is less than 1 × 10⁻⁶; (2) the relative change in the magnetic flux density between adjacent iterations at the monitoring points in the separation zone is less than 5 × 10⁻⁷. The simulation result of the magnetic field distribution at the central cross-section of the model is presented in Figure 4.

3.3. Reliability Verification

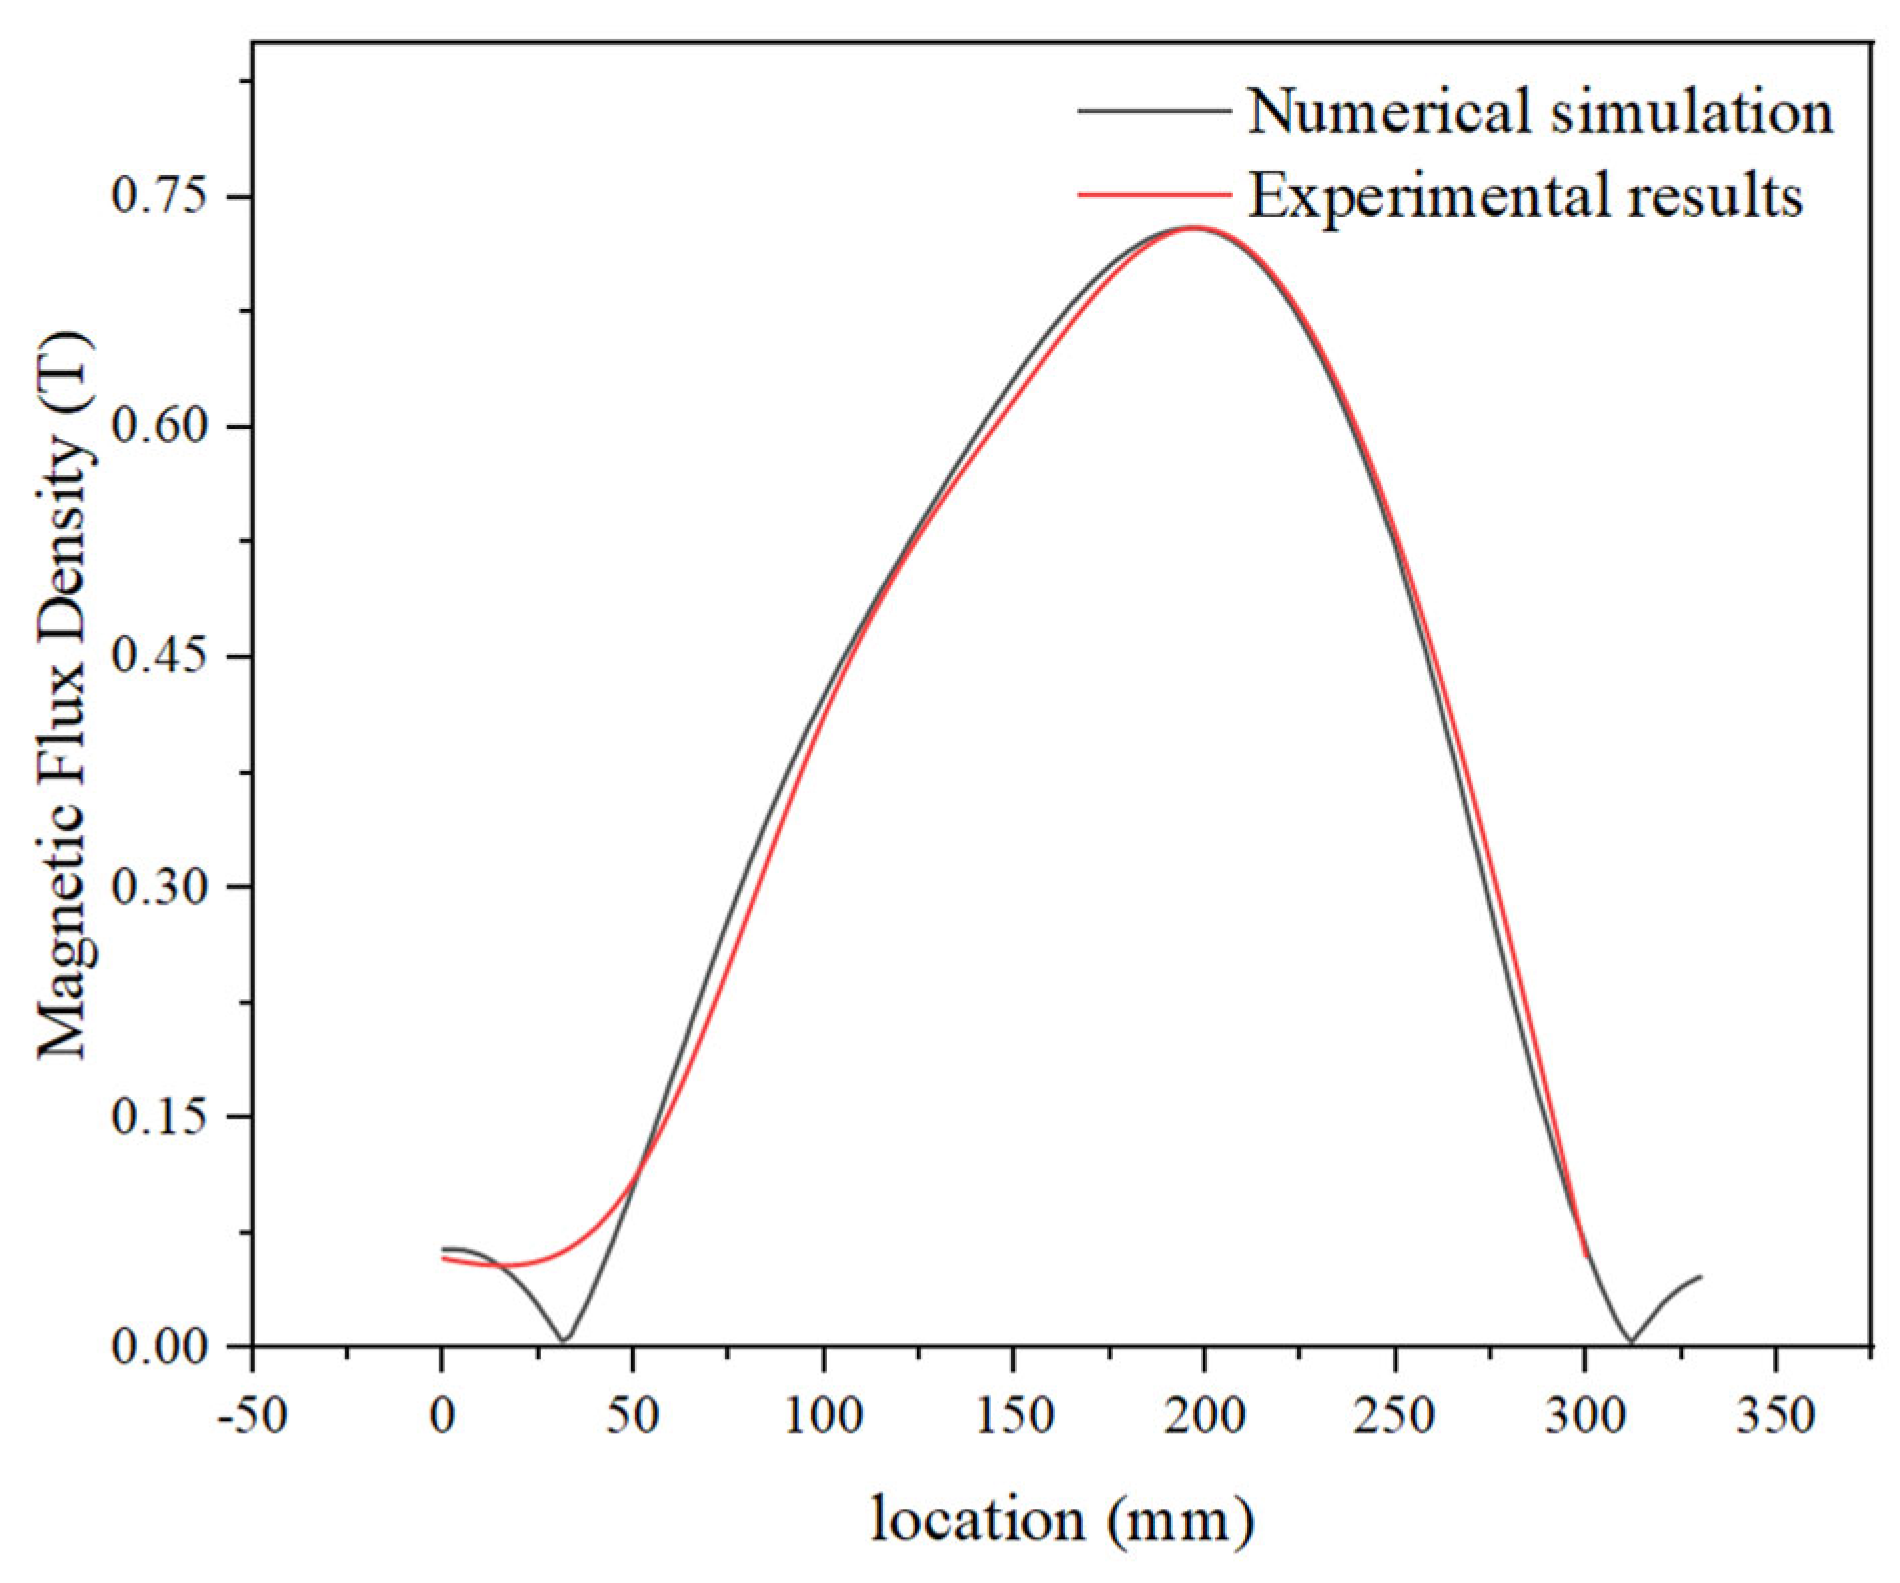
To verify the reliability of the simulation results, a test device of the isodynamic permanent magnetic field system shown in Figure 1 was built. The parameters of the magnetic system are as follows: the large arc radius of the curved pole head is 300 mm, the arc center angle is 25°, the thickness of the patch magnet on the side of the curved pole head is 50 mm, both the curved pole head and the yoke plate are made of No. 10 steel, the permanent magnet adopts N45-grade neodymium-iron-boron (NdFeB) blocks with a remanence of 1.35 T and a coercivity of 876 kA/m, and the working air gap of the magnetic system is 50 mm. A WT10A digital Gaussmeter was used to measure the magnetic induction intensity at the central axis of the magnetic system, and the measured results were compared with the simulation results. The comparison between the simulated and measured values of the magnetic induction intensity at the central axis of the magnetic system obtained by finite element simulation is shown in Figure 5.
As shown in Figure 5, the finite element numerical simulation results of magnetic induction intensity along the central axis of the isodynamic magnetic system are in good agreement with the experimentally measured results, and their overall variation trends are highly consistent. The relative error between the simulated values and the measured values is 0.5%~5%, which fully validates the accuracy and reliability of the numerical calculation model established in this study for magnetic field characteristic analysis.

4. Results and Discussion

4.1. Influence of Curved Pole Tips on Interpolar Magnetic Fields

The curved pole tips guide magnetic flux into the separation zone, thereby creating a precisely controlled isodynamic magnetic field. Notably, the geometric parameters of the pole tips exert a significant influence on the field distribution within the separation zone. Systematic variation in the pole tip curvature and dimensions enables a comprehensive analysis of the effects of these parameters on the characteristics of the separation field.

4.1.1. Effect of Pole Tip Geometry on Magnetic Field Configuration

The curved pole tips consist of two mutually tangent circular arcs with compound curvature. Systematic variations in arc radii and central angles exert a substantial influence on magnetic field distributions. Under controlled experimental conditions (major arc radius: 300 mm, minor arc radius: 150 mm, inter-pole gap: 50 mm), the central angles were systematically varied over 20°, 25°, and 30° to quantitatively assess how magnetic field characteristics depend on the central angle.
As illustrated in Figure 6, the radial distribution of the magnetic field shows a consistent variation pattern regardless of the change in central angle, provided that the major and minor arc radii, permanent magnet configuration, and inter-pole working air gap remain unchanged. The interpolar magnetic field presents non-uniform radial characteristics, with the maximum magnetic field intensity appearing at the apex of the curved pole head. The magnetic field intensity exhibits a gradual decay along the −x direction of the central axis, while a sharp decline occurs along the +x direction.
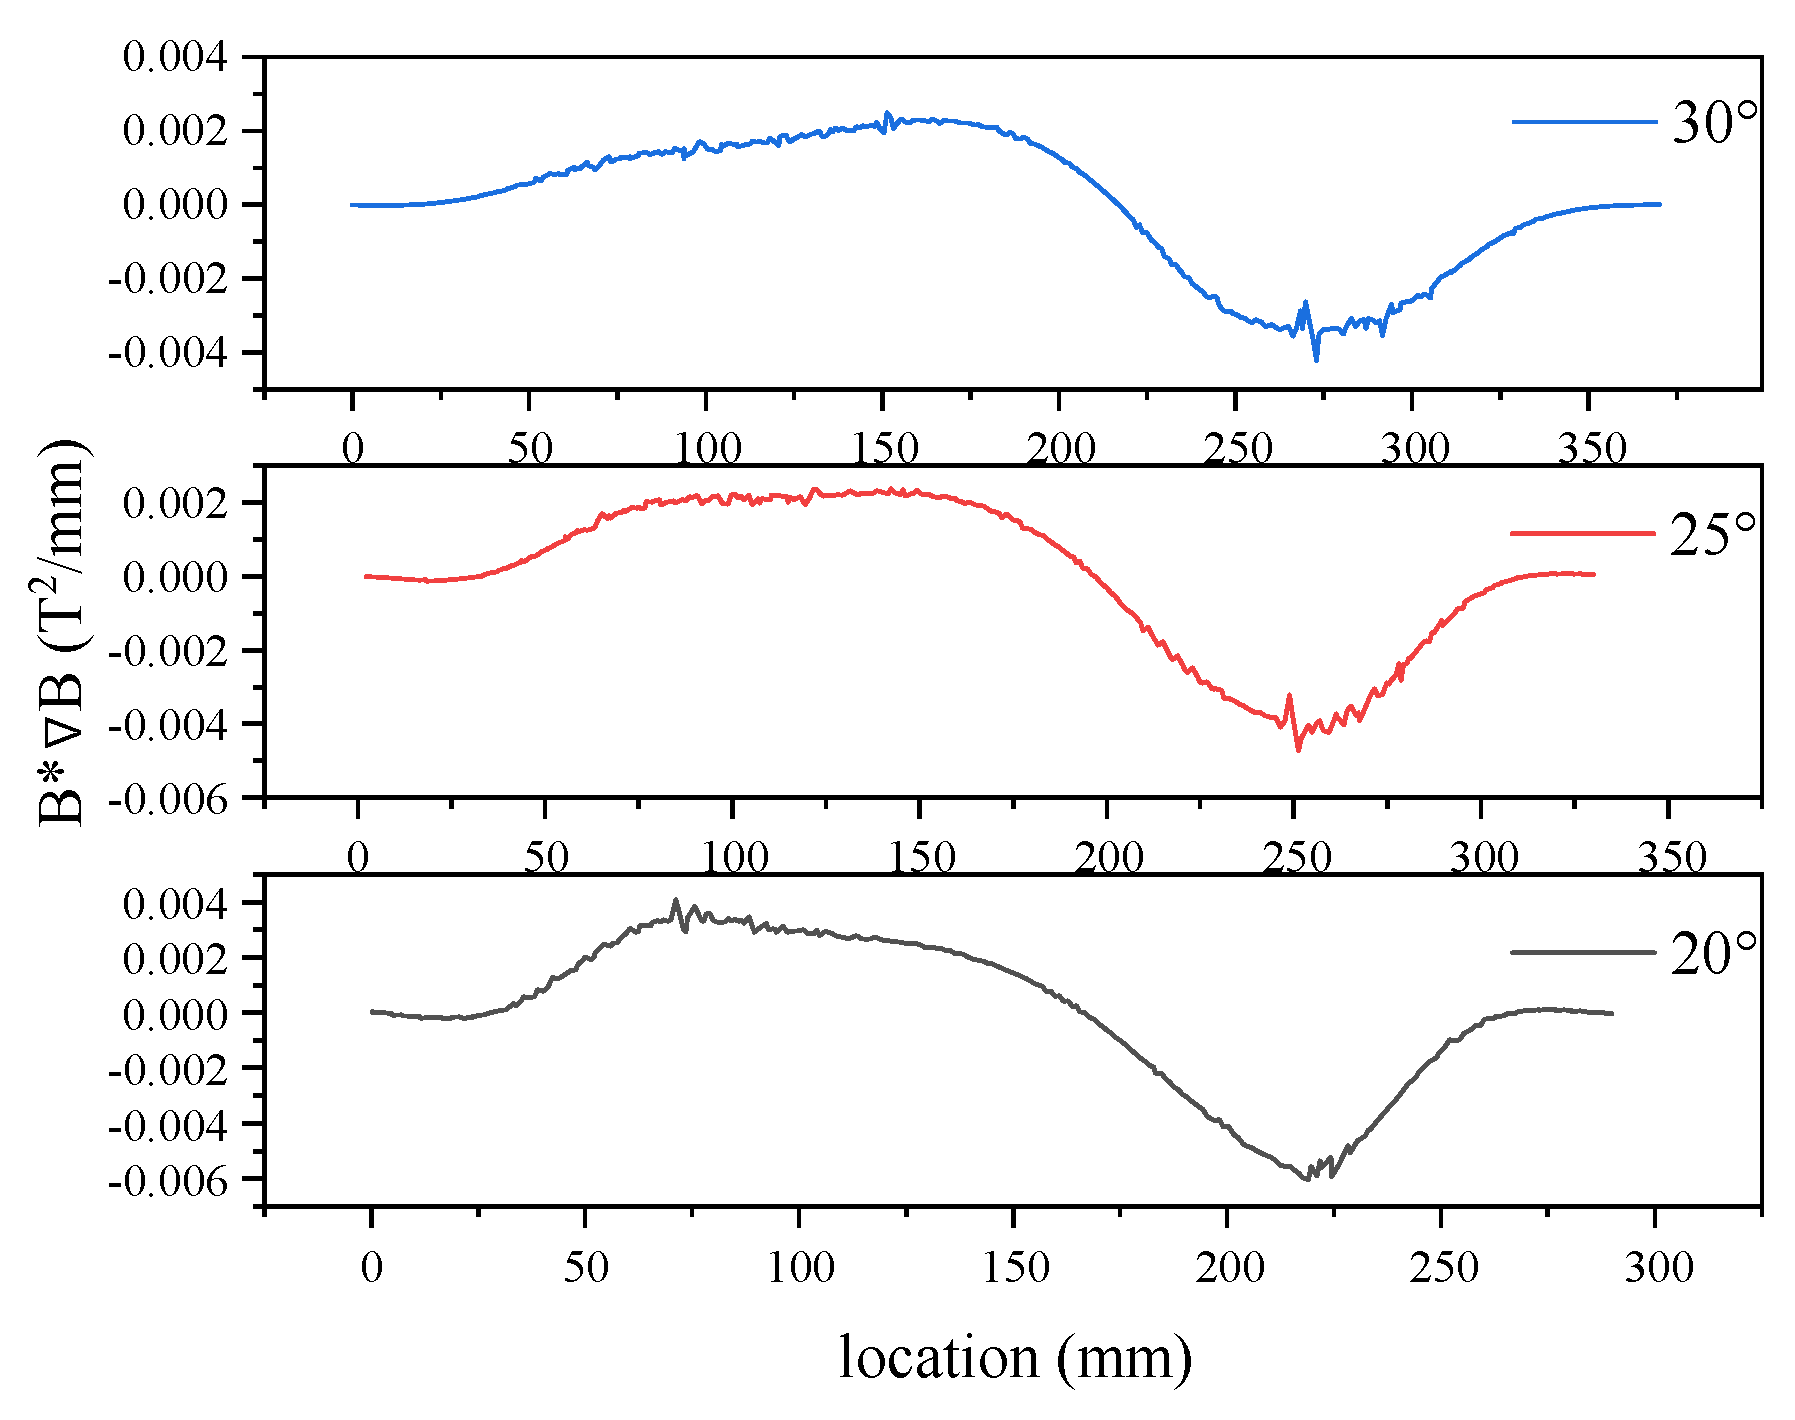
As established by the aforementioned theoretical derivation in this study, the magnetostatic force acting on the target mineral particles in the separation zone is proportional to the product of the magnetic flux density (B) and its spatial gradient (∇B). The magnetic field gradient along the interpolar central axis was calculated via numerical differentiation of the axial magnetic field strength distribution obtained from the finite element simulation. Subsequently, the force parameter B·∇B for isodynamic magnetic field characterization was obtained through element-wise multiplication. The spatial variation characteristics of this critical magnetic force parameter along the central axis of the separation zone are presented in Figure 7.
As revealed in Figure 7, an isodynamic magnetic field is achieved within the separation zone exclusively when the central angle of the curved pole heads is 25°. Deviation from this optimal geometry—whether the central angle increases to 30° or decreases to 20°—compromises the uniformity of the magnetic force field, thereby resulting in non-isodynamic magnetic field conditions. The underlying mechanism is attributed to the variation in the magnetic field gradient along the interpolar central axis caused by the adjustment of the central angle. When the central angle increases to 30°, the magnetic field on the left side of the separation zone (along the −x direction of the central axis) changes gently, leading to a significant decrease in the magnetic field gradient. This further reduces the value of the force parameter B·∇B, and eventually deteriorates the uniformity of the magnetic force field. In contrast, when the central angle decreases to 20°, the magnetic field in the same region changes sharply, resulting in an excessive magnetic field gradient. This causes the value of B·∇B to increase abnormally, which also destroys the spatial uniformity of the magnetic force field. This result indicates that there exists a critical angular range for the curved pole-head configuration to generate the target isodynamic force field.
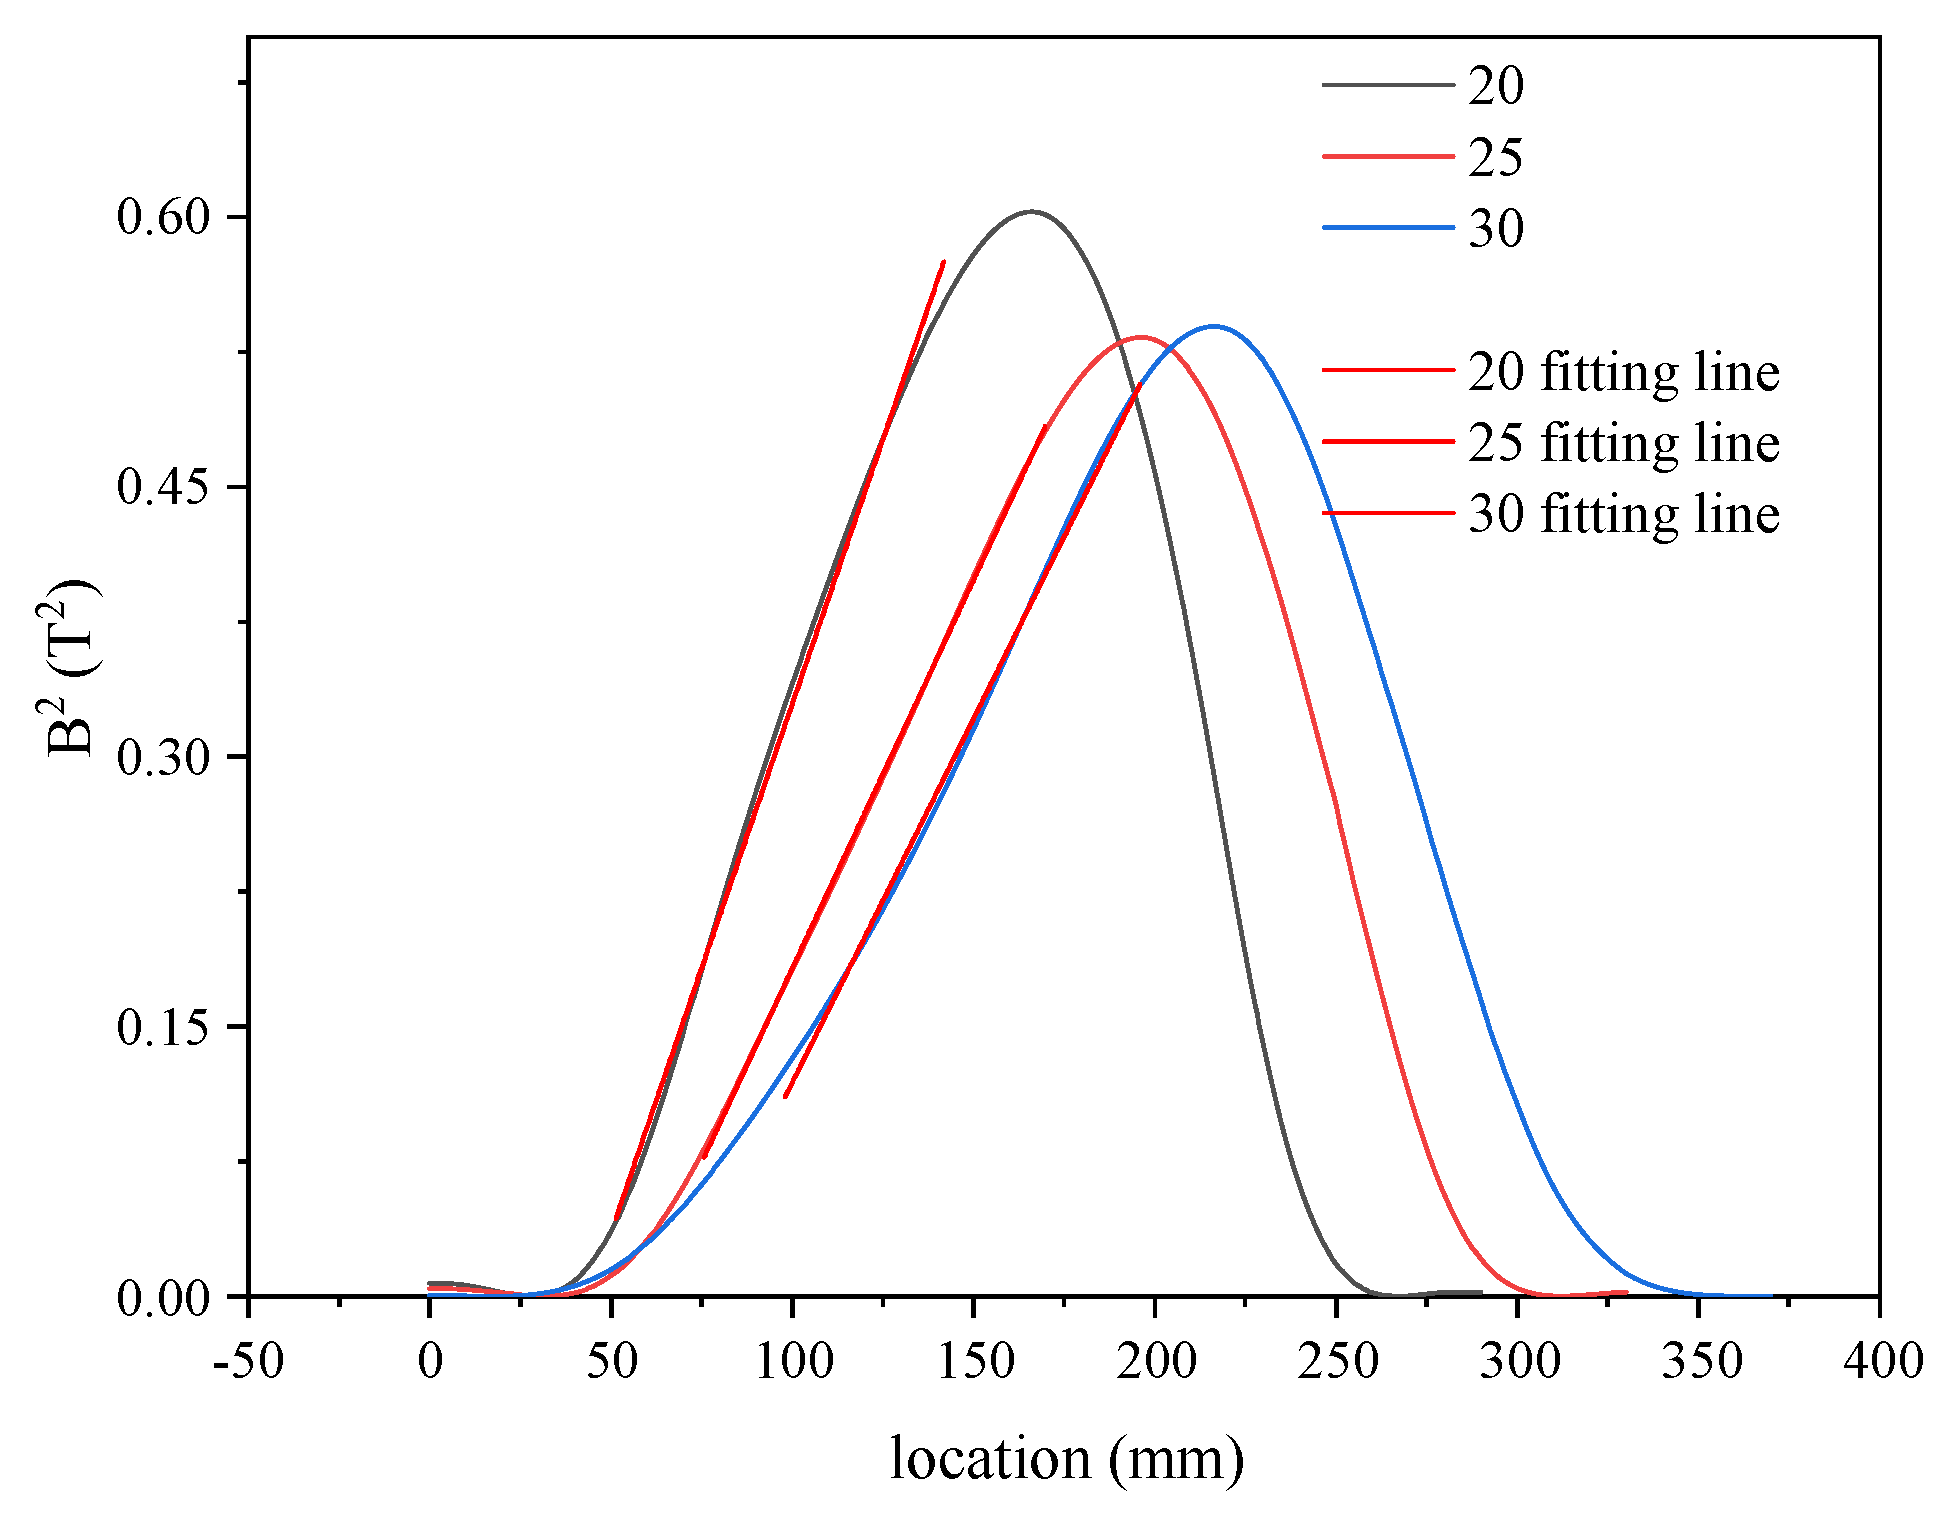
Furthermore, as established by the aforementioned theoretical derivation, the squared magnetic flux density (B2) must exhibit a strict linear relationship with the spatial position along the interpolar central axis in an ideal isodynamic magnetic field. This linear correlation was verified using the curve-fitting module of the Origin software (version 2021). The comparative plots of the measured B2 values versus spatial position along the central axis, as well as their corresponding linear regression fitting results, are presented in Figure 8.
As presented in Table 3, when the coefficient of determination (R2) of the linear fit between B2 and spatial position exceeds 0.999, the spatial distribution profile of the force parameter B·∇B verifies that the target mineral particles are subjected to a constant magnetostatic force throughout the entire separation zone. Thus, R2 > 0.999 for the linear fitting of B2 versus spatial position serves as a reliable quantitative indicator for the effective construction of an isodynamic magnetic field. Conversely, R2 < 0.999 indicates that the required uniformity of the target magnetic force field cannot be achieved. It is further confirmed that a uniform magnetic field can be established in the separation zone only when the central angle of the curved pole head is 25°. Any deviation from this optimal angle, whether increasing to 30° or decreasing to 20°, impairs the magnetic field uniformity and precludes the formation of an isodynamic magnetic field.
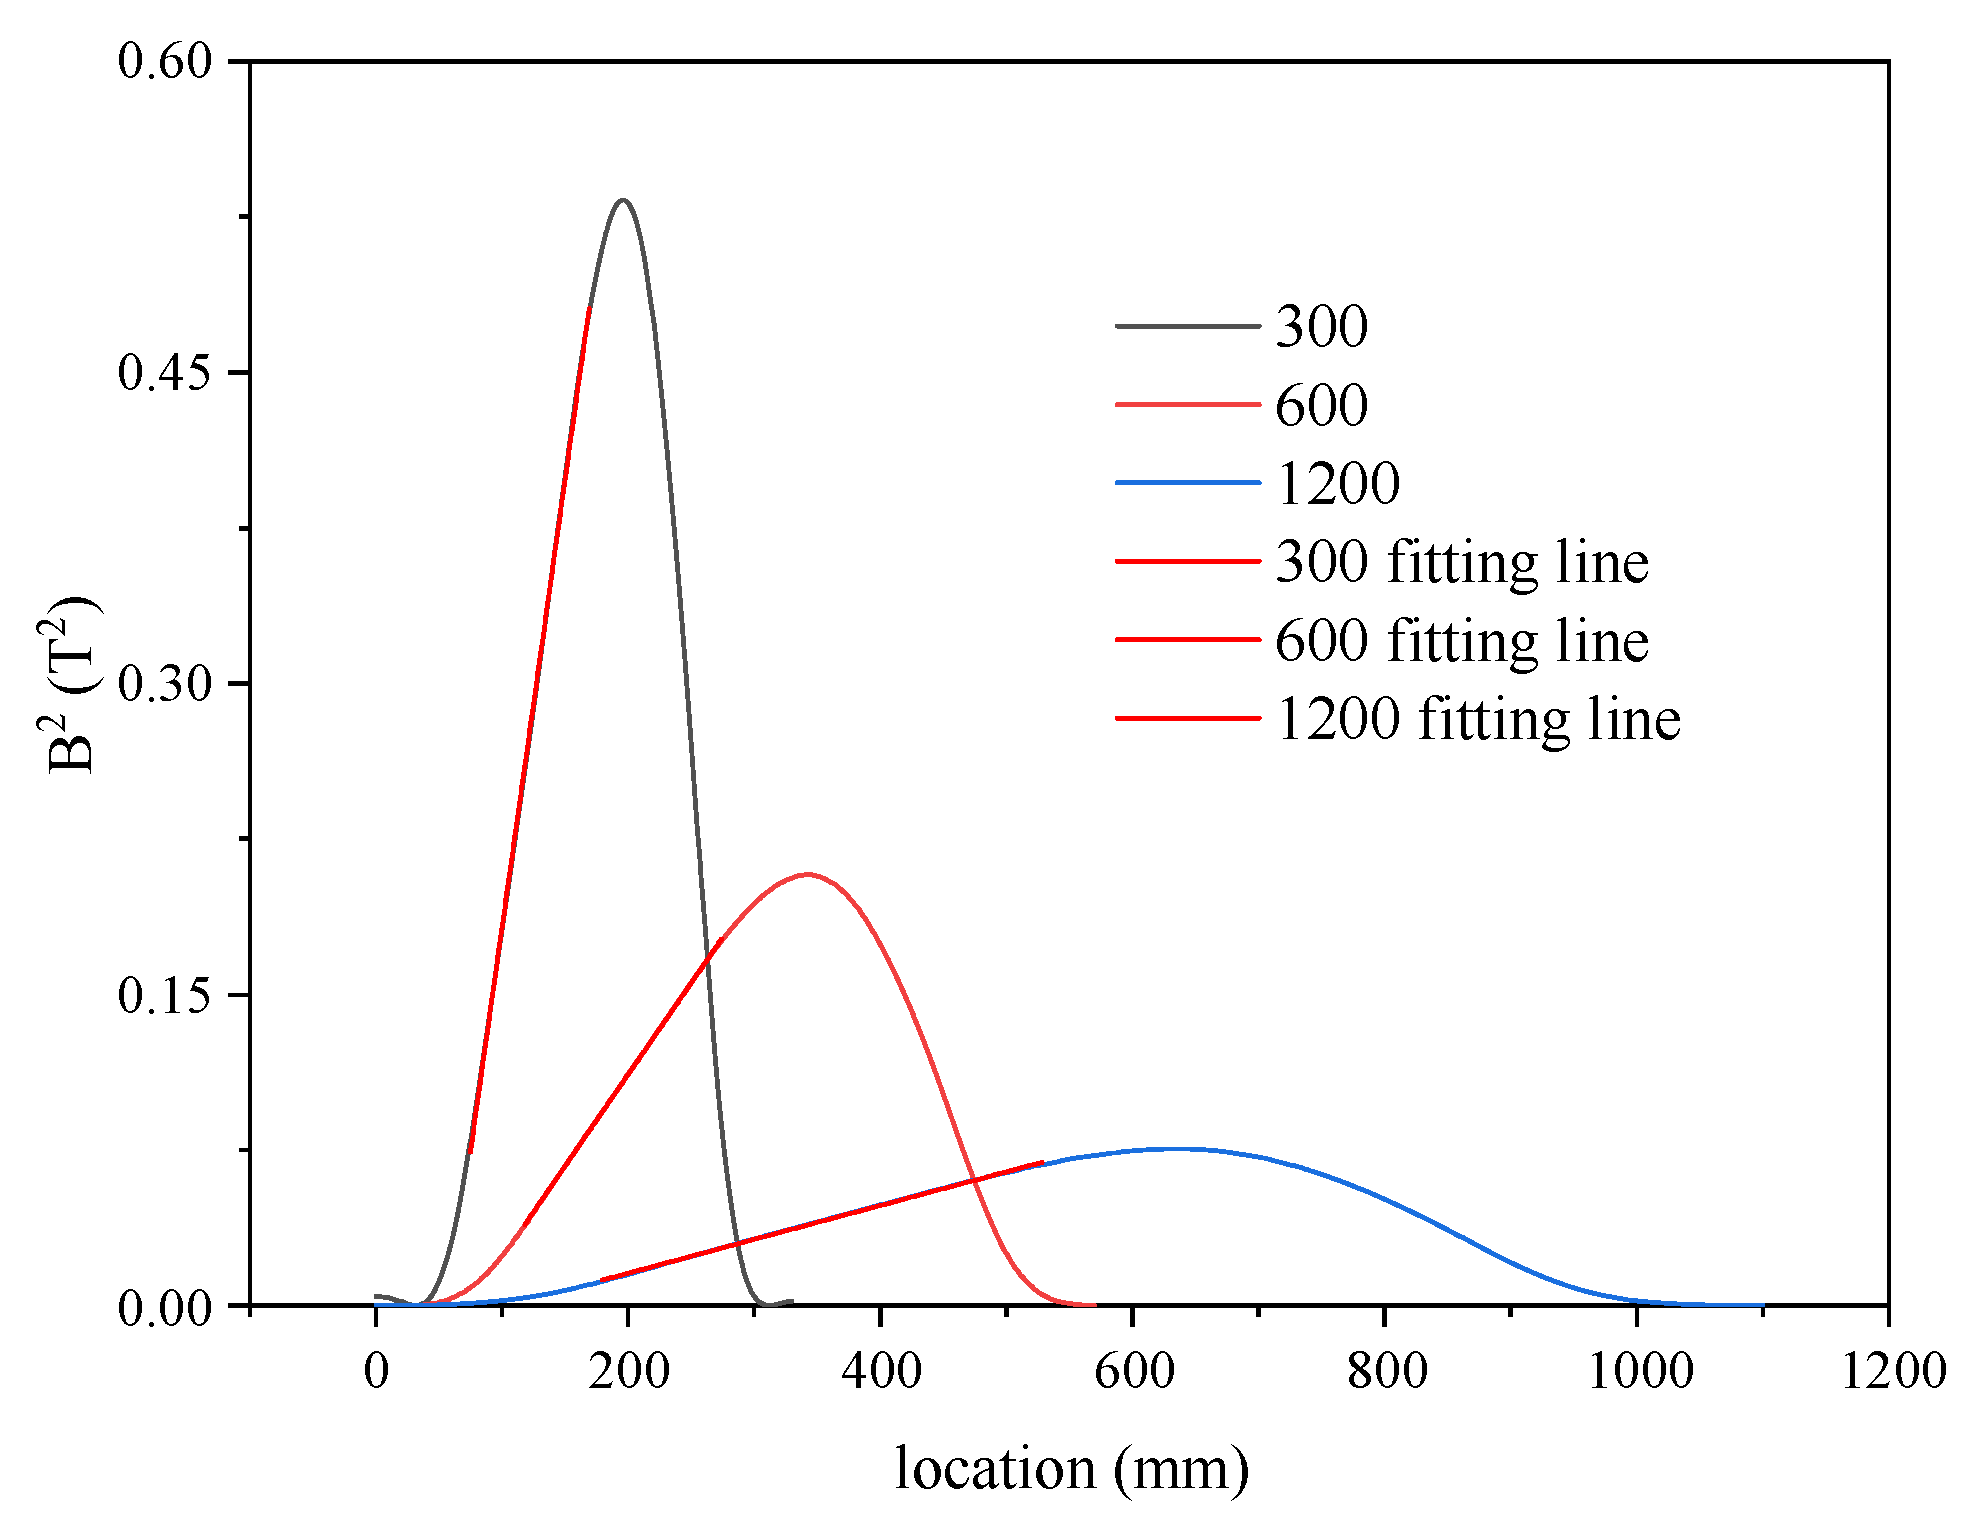
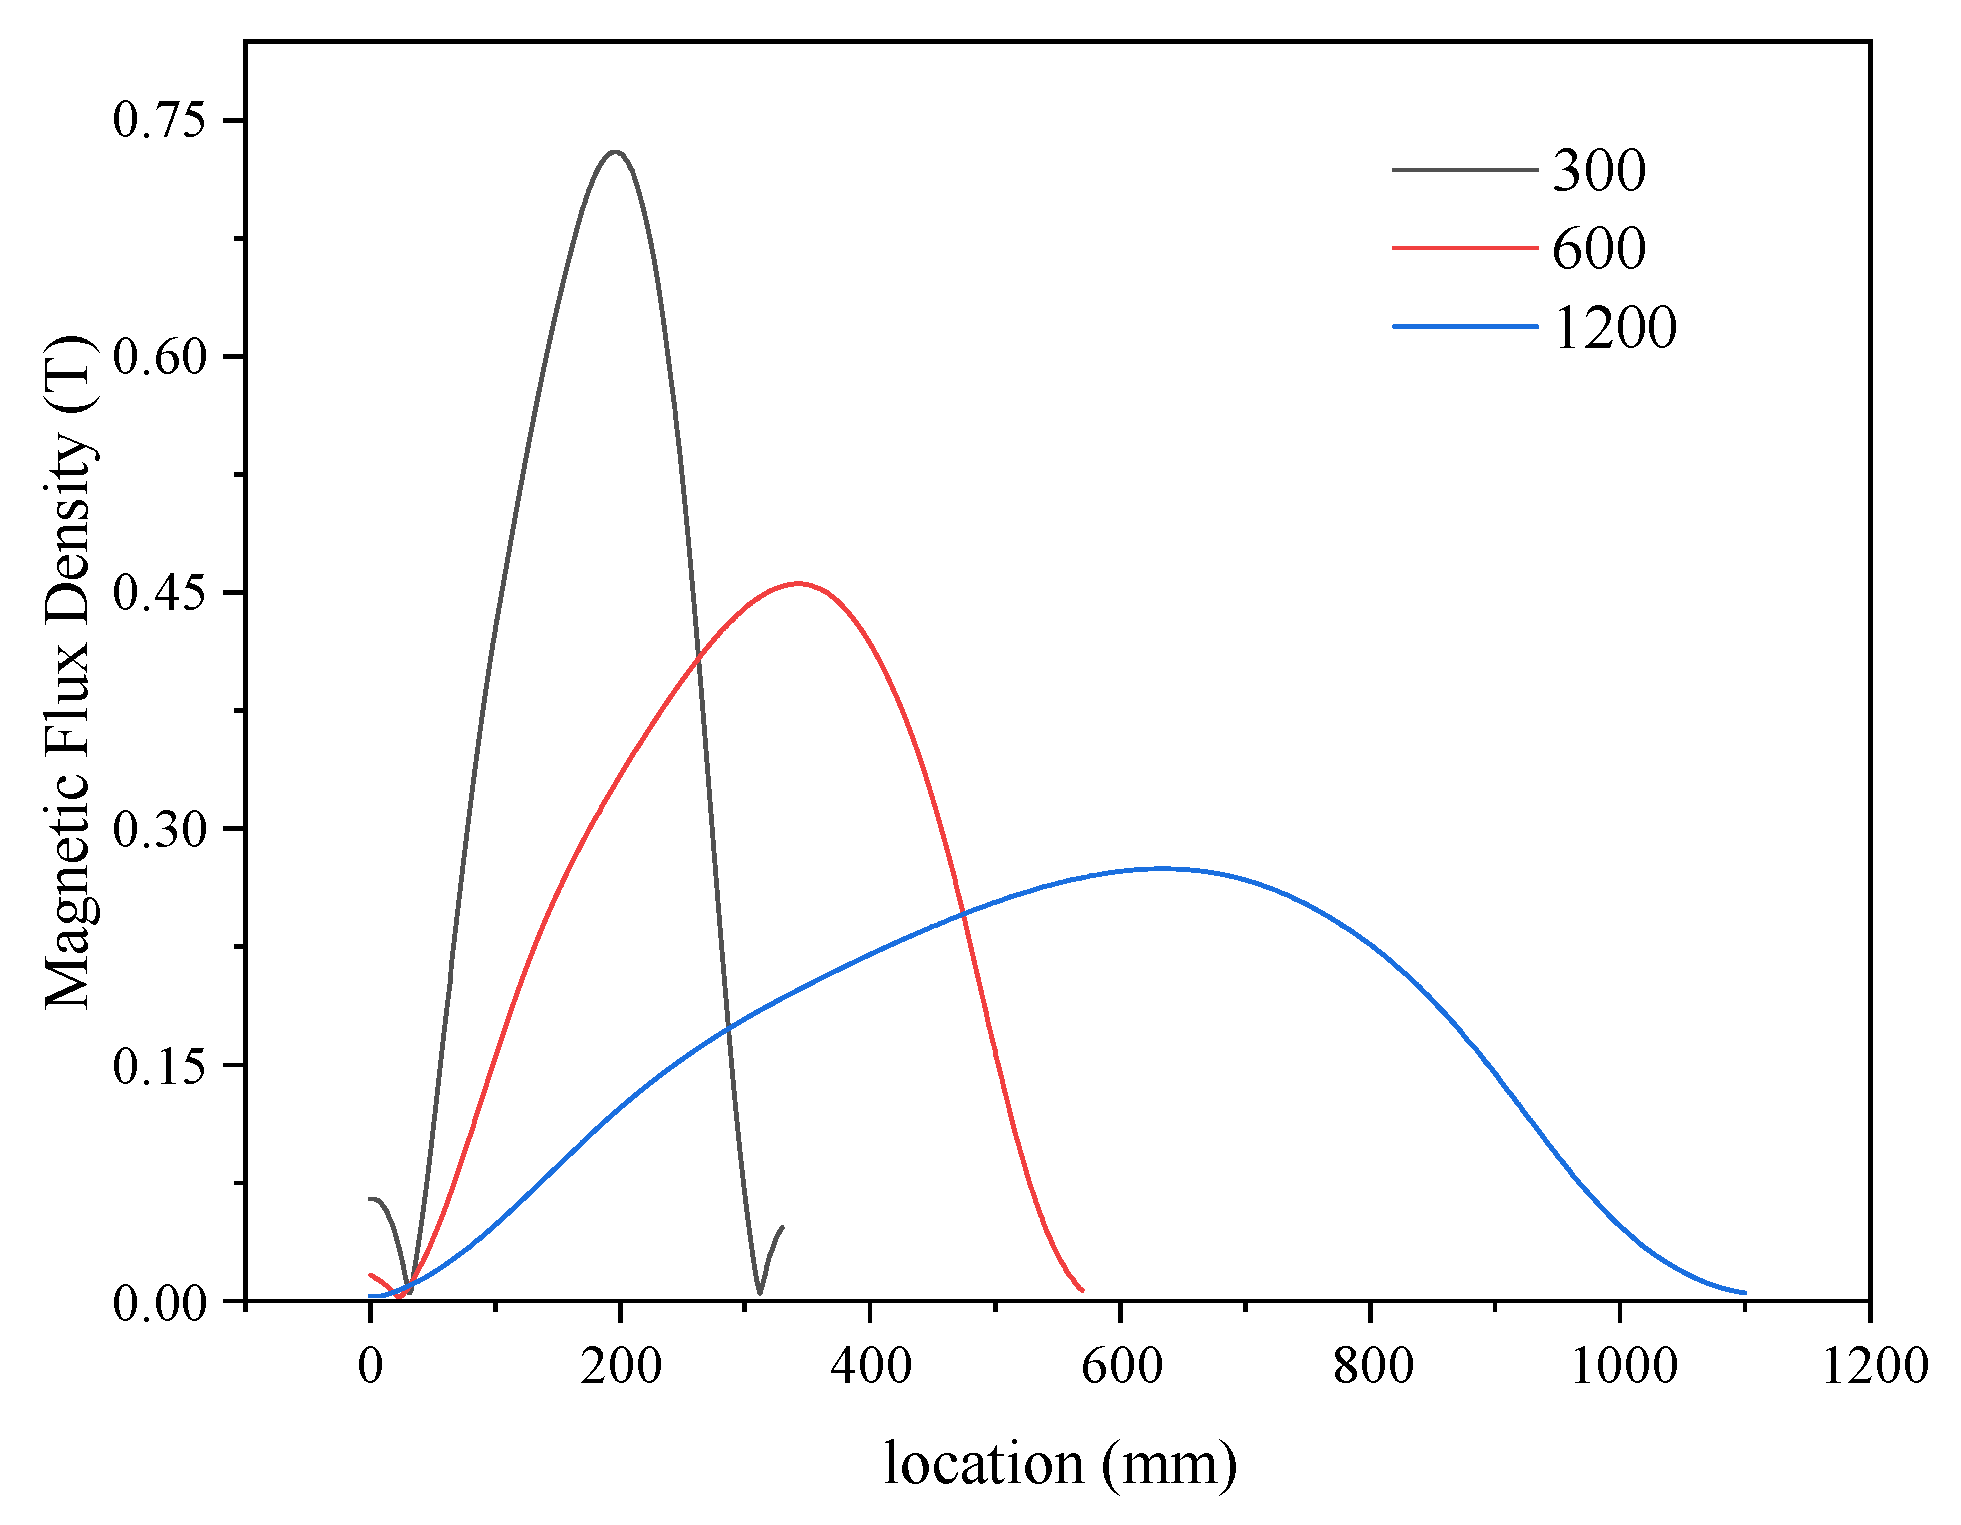
In the practical design of isodynamic magnetic separators, the geometric scaling of the magnetic system often impairs separation efficiency. To systematically evaluate the influence of geometric scaling while maintaining the geometric proportionality of the curved pole heads, the magnetic system was proportionally scaled up by increasing the major arc radius of the pole heads. Under identical material properties, boundary conditions and operational parameters, numerical simulations were carried out for the isodynamic magnetic systems with major arc radii of 300 mm, 600 mm and 1200 mm. The spatial distribution profiles of key performance parameters, including the axial magnetic flux density (B) along the interpolar central axis, the squared magnetic flux density (B2), and the force parameter (B·∇B), were obtained as a function of spatial position. Meanwhile, linear regression analysis was performed on the B2 data within the separation zone.
As shown in Figure 9, geometric scaling of the magnetic system induces a reduction in the peak magnetic field strength at the interpolar central axis, and the magnitude of this reduction is inversely proportional to the size of the magnetic system. Notably, the interpolar magnetic field retains its inherent radially non-uniform distribution characteristics regardless of the geometric scaling ratio. The magnetic field strength decreases with increasing distance from the apex of the curved pole heads, displaying asymmetric decay behavior: a gradual reduction along the −x direction of the central axis, in contrast to an abrupt decline along the +x direction of the central axis.
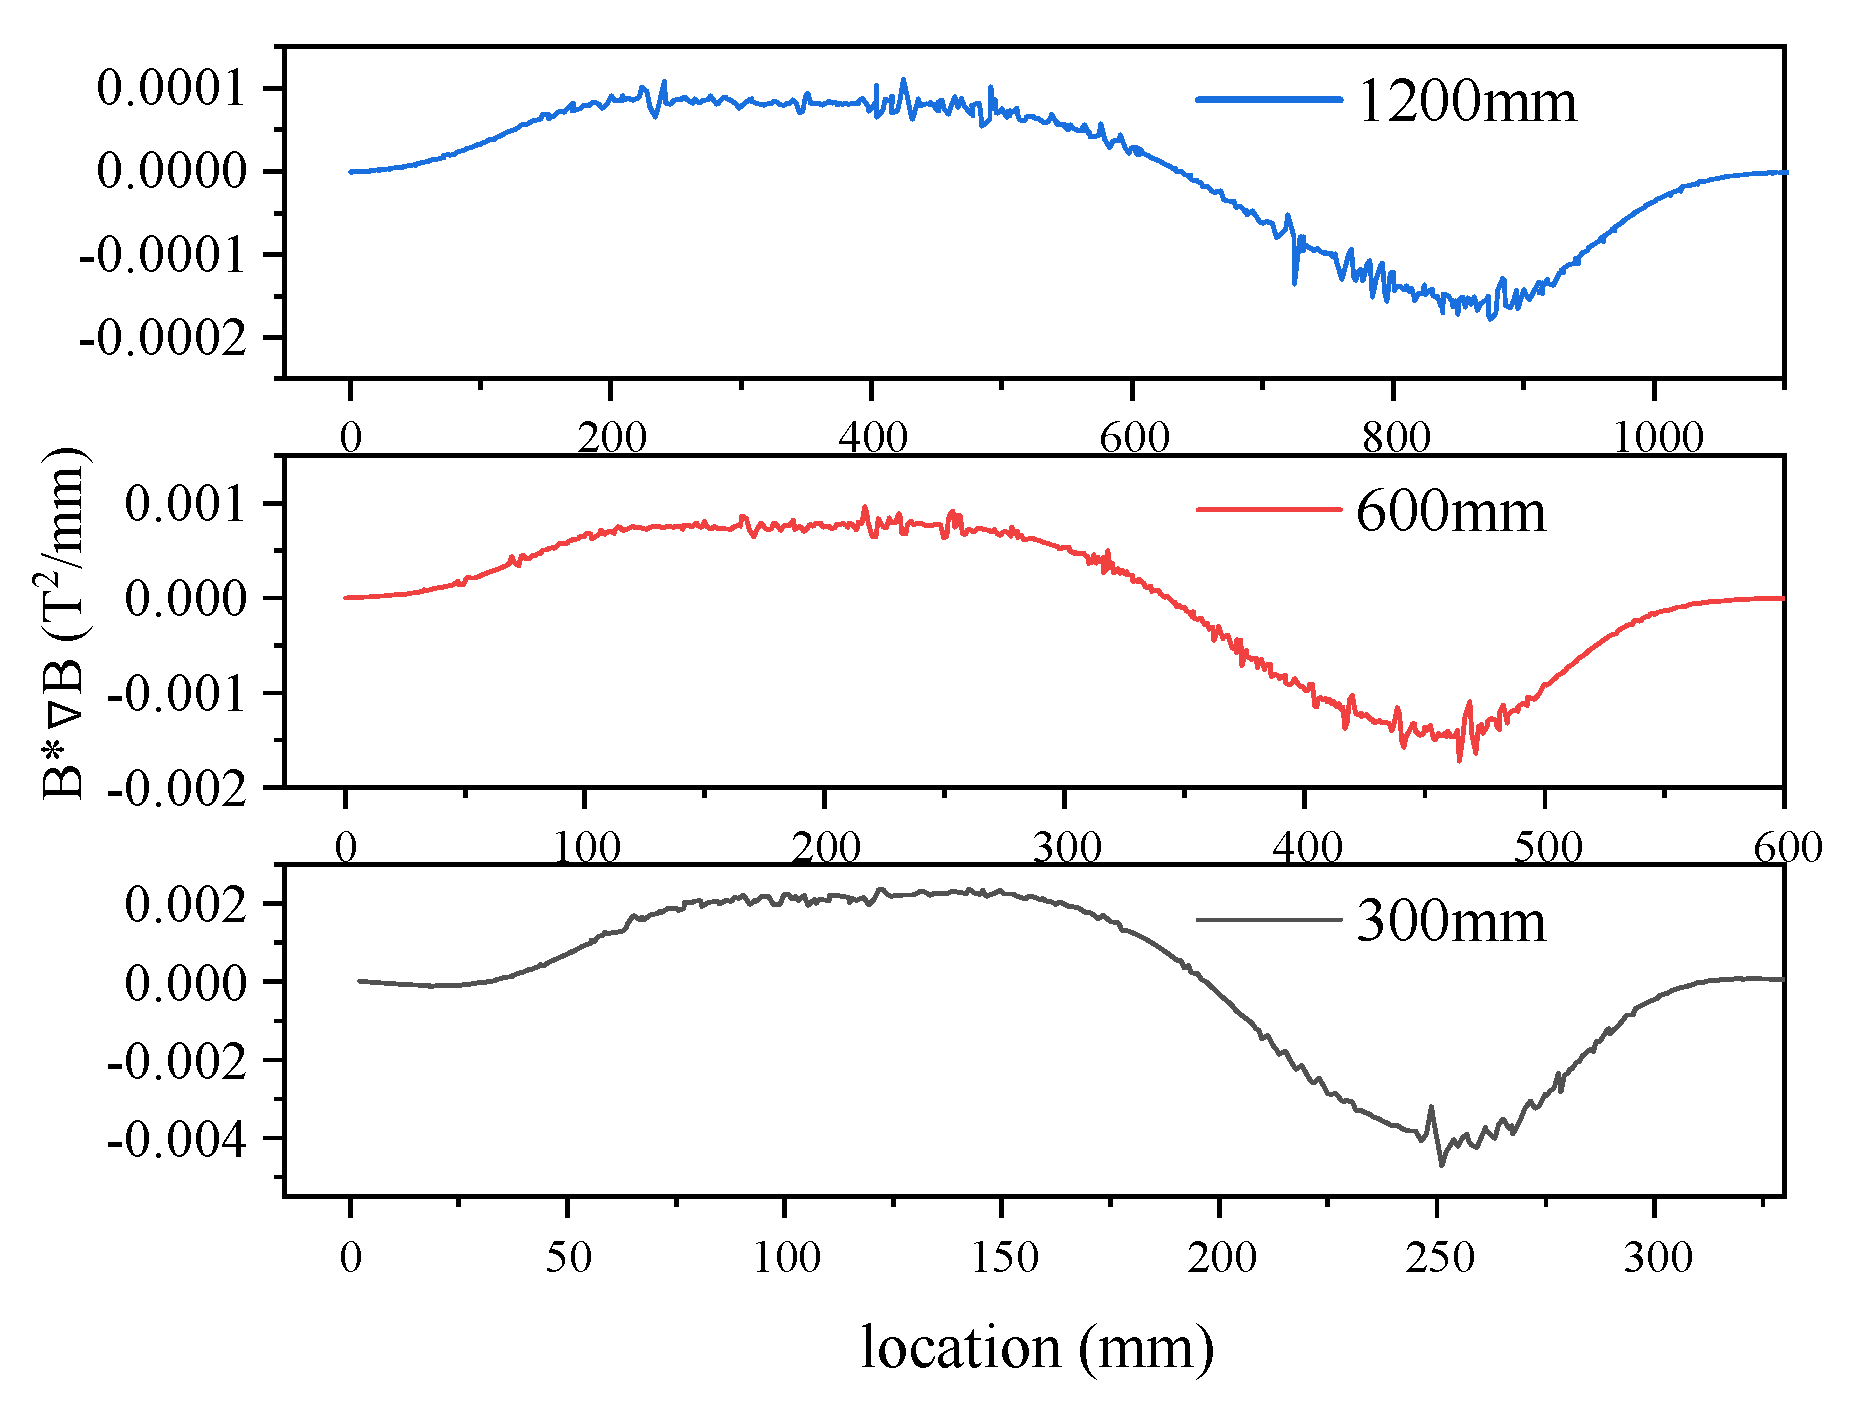
As depicted in Figure 10, the axial distribution characteristics of both the magnetic flux density (B) and the magnetic field gradient magnitude (∇B) for the proportionally scaled magnetic system configurations were characterized via the numerical analysis methodology established in this study.
As revealed in Figure 10, geometric scaling of the magnetic system results in an inverse relationship between the dimensions of the magnetic system and the magnetostatic force (characterized by the force parameter B∙∇B) exerted on the target mineral particles in the separation zone. Importantly, while geometric scaling affects the magnitude of the magnetic force, the inherent spatial distribution pattern of the magnetic force field is fully preserved, and asymmetric force profiles are maintained across all proportionally scaled magnetic system configurations. Most significantly, the enlargement of the magnetic system leads to a proportional increase in the effective working area of the isodynamic magnetic field within the separation zone.
Under these identical control conditions, Figure 11 depicts the squared magnetic flux density (B2) versus spatial position curves, along with the corresponding linear regression fitting results for the scaled curved pole-head configurations, with the detailed fitting parameters summarized in Table 4.
The experimental and numerical simulation results indicate that, at a major arc radius of 300 mm, the coefficient of determination (R2) for the linear regression of B2 versus spatial position within the separation zone exceeds 0.999, which confirms the effective construction of the target isodynamic magnetic field. Notably, this high magnetic force field uniformity (with R2 > 0.999) is fully maintained in the geometrically scaled curved pole-head configurations at major arc radii of 600 mm and 1200 mm. Two distinct scaling effects of the isodynamic magnetic system were identified in this study: (1) both the magnetic flux density and the resultant magnetostatic force exerted on the target mineral particles exhibit an inverse proportional relationship with the overall dimensions of the magnetic system; (2) the effective working area of the isodynamic magnetic field expands proportionally with the scaling-up ratio of the magnetic system.

4.1.2. Influence of Magnet Block Parameters on Magnetic Field Characteristics

The isodynamic magnetic system is mainly composed of curved pole heads and permanent magnet blocks, which serve as the magnetic field source of the system. Accordingly, both the performance grade of the permanent magnet blocks and their spatial assembly configuration exert a dominant influence on the magnetic field distribution and magnetic force field uniformity in the separation zone. To systematically investigate the influence of permanent magnet parameters on the isodynamic magnetic field characteristics, we carried out single-factor controlled variable analysis on two categories of parameters: the grade of the permanent magnet material and the geometric spatial arrangement of the permanent magnet blocks.
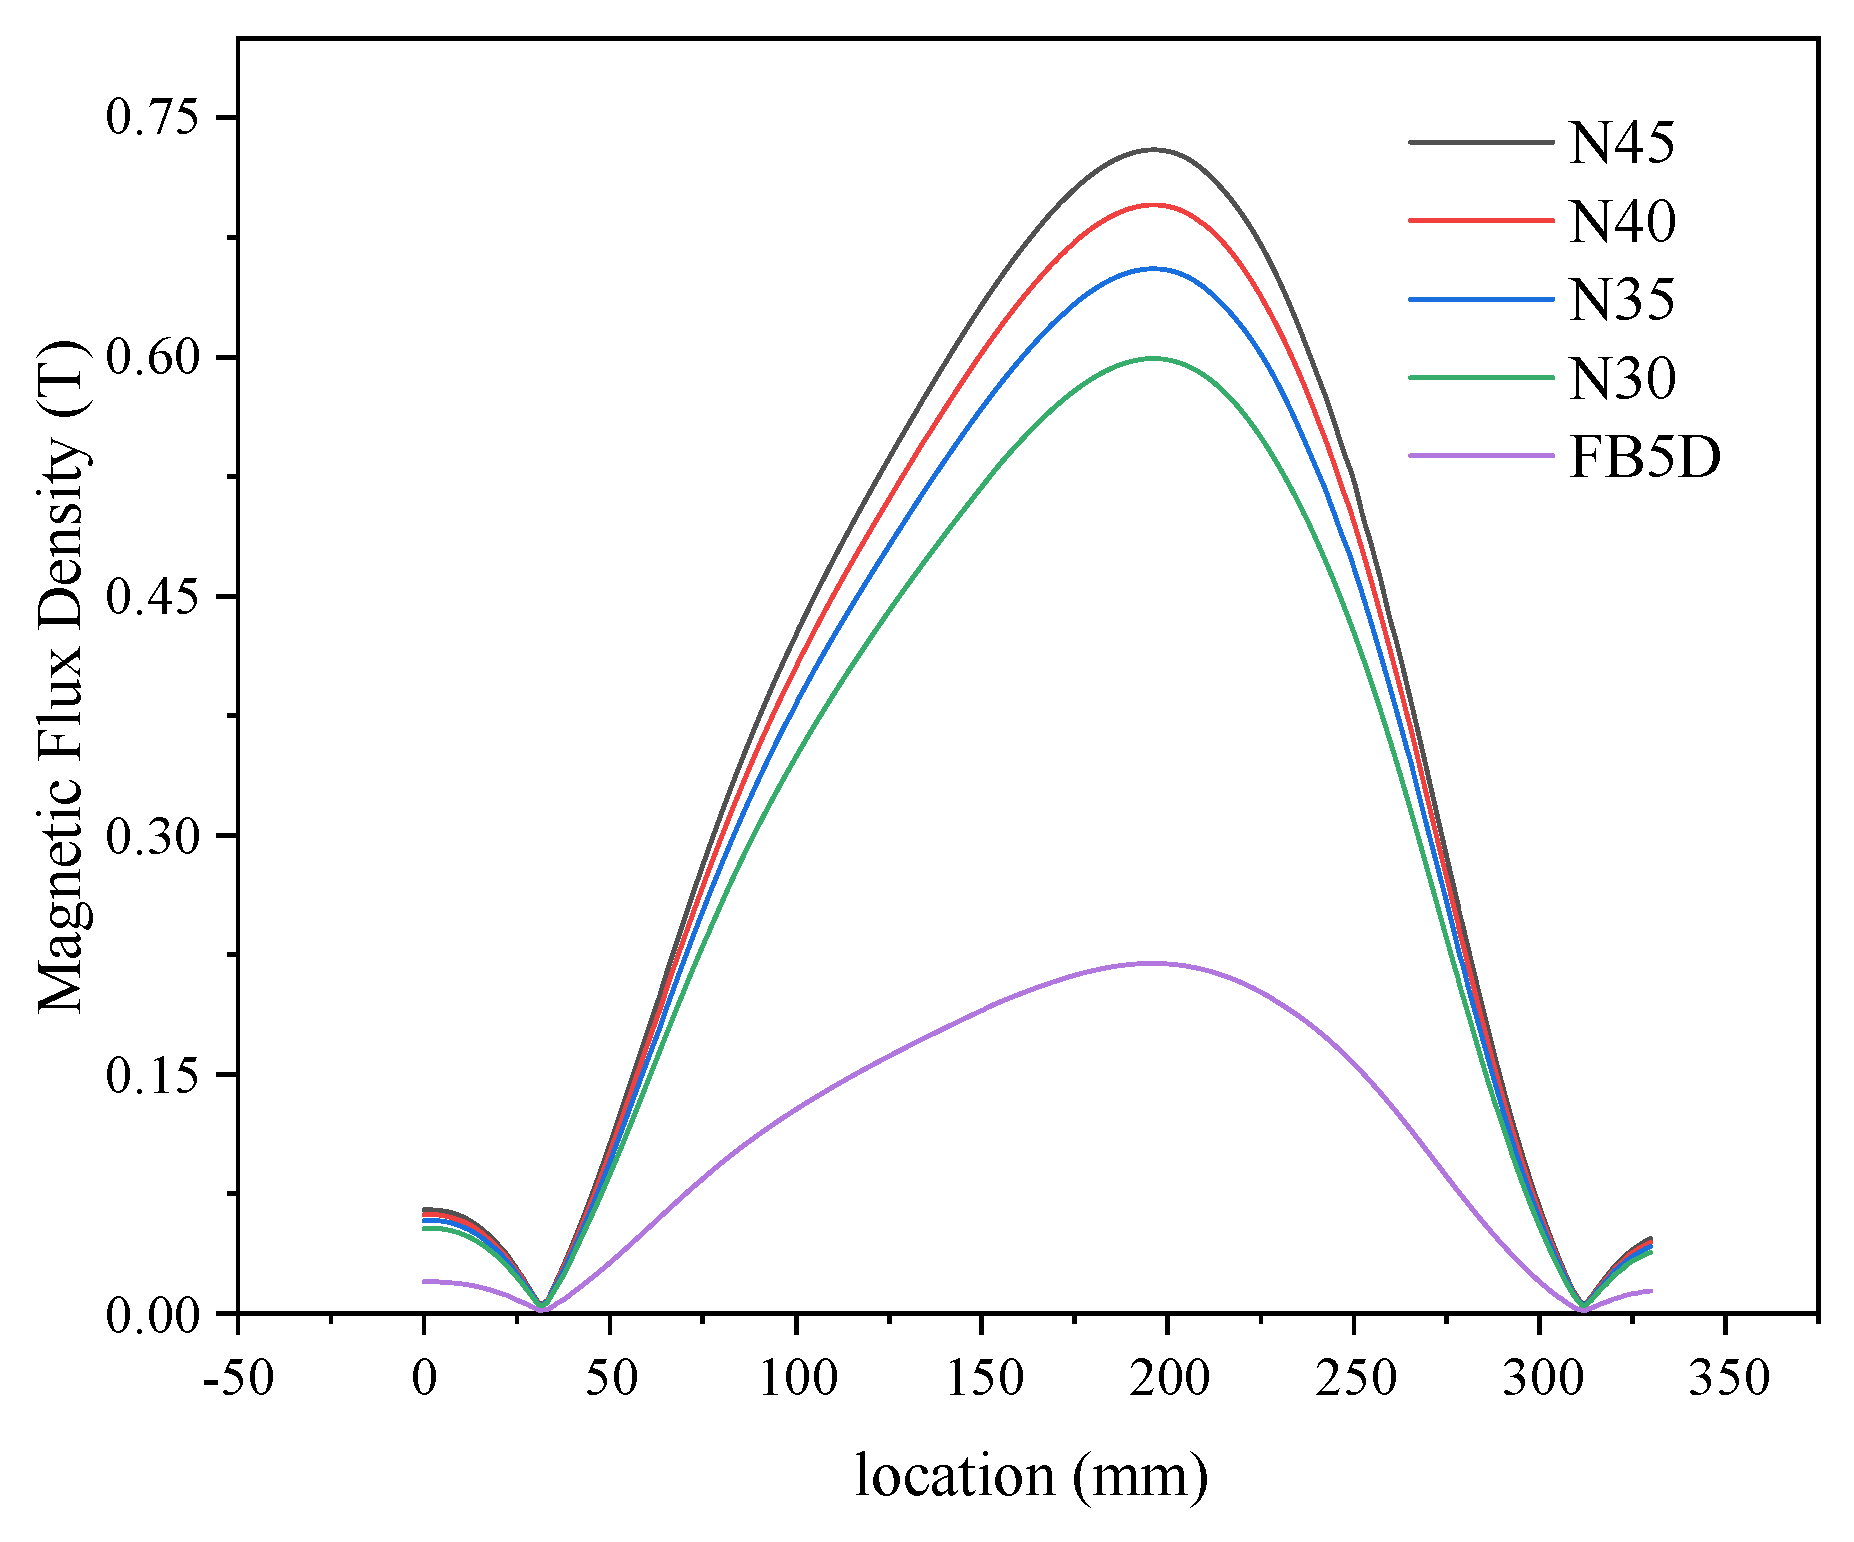
Under the condition of fixed geometric parameters of the curved pole heads, the permanent magnet materials adjacent to the pole heads were systematically replaced, with all other operational and structural parameters held constant. Numerical simulations were carried out to evaluate four grades of neodymium iron boron (NdFeB) permanent magnets (N45, N40, N35, N30) as well as ferrite magnets (FB5D), to quantitatively assess their respective impacts on the magnetic field strength in the separation zone.
As illustrated by the numerical simulation results, increasing the magnetic energy product of the permanent magnet blocks assembled on the back of the curved pole heads leads to a significant increase in the peak magnetic flux density (B) along the interpolar central axis. Crucially, varying the type of permanent magnet material only affects the magnitude of the magnetic field strength, and does not alter the inherent radial non-uniformity distribution characteristics of the interpolar magnetic field. The magnetic field strength decreases continuously with increasing distance from the apex of the curved pole heads.
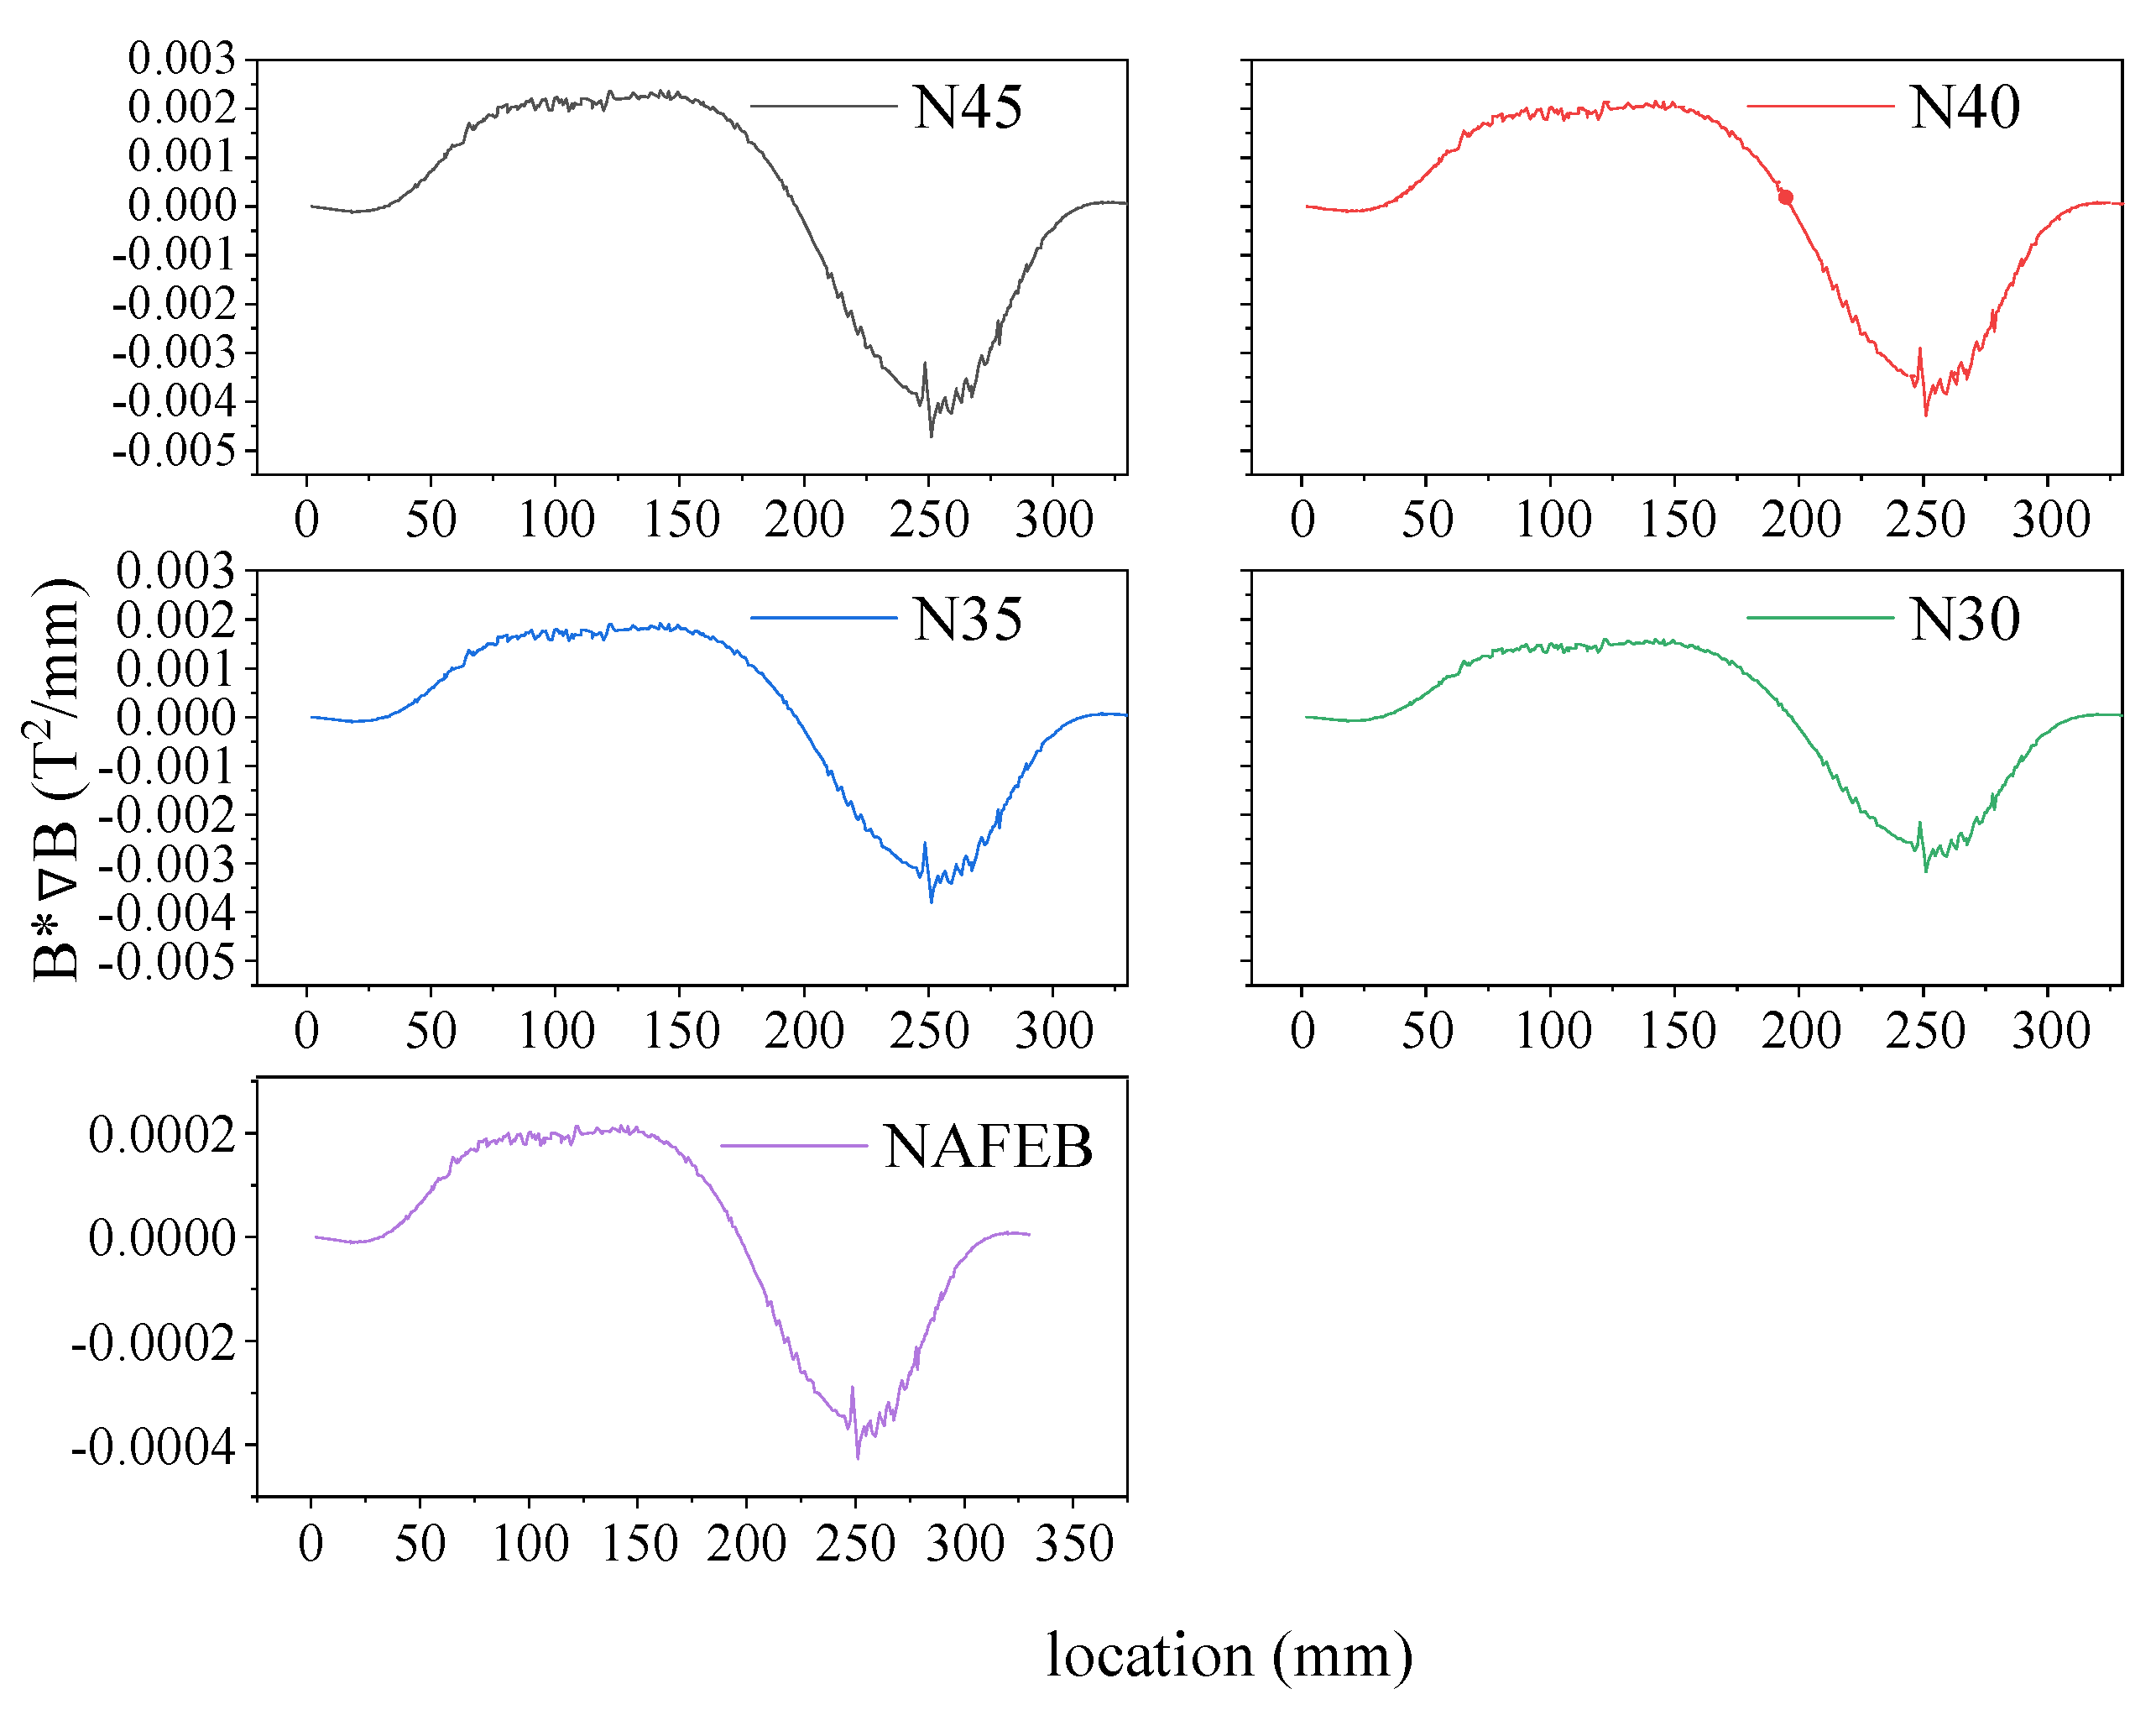
Via the numerical analysis methodology established in this study, Figure 12 depicts the axial distribution profiles of the magnetic force parameter (B·∇B) along the inter-pole central axis for different types of permanent magnet materials.
As illustrated in Figure 13, increasing the magnetic energy product of the permanent magnet blocks assembled on the back of the curved pole heads leads to a strictly proportional increase in the magnetostatic force acting on the target mineral particles in the separation zone. Notably, the inherent spatial distribution characteristics of the magnetic force field remain fully preserved regardless of the variation in permanent magnet material grade and type. Furthermore, although higher-grade permanent magnet materials significantly increase the magnitude of the magnetostatic force in the separation zone, the spatial extent and effective working area of the isodynamic magnetic field maintain complete geometric invariance under the identical structural configuration of the magnetic system.
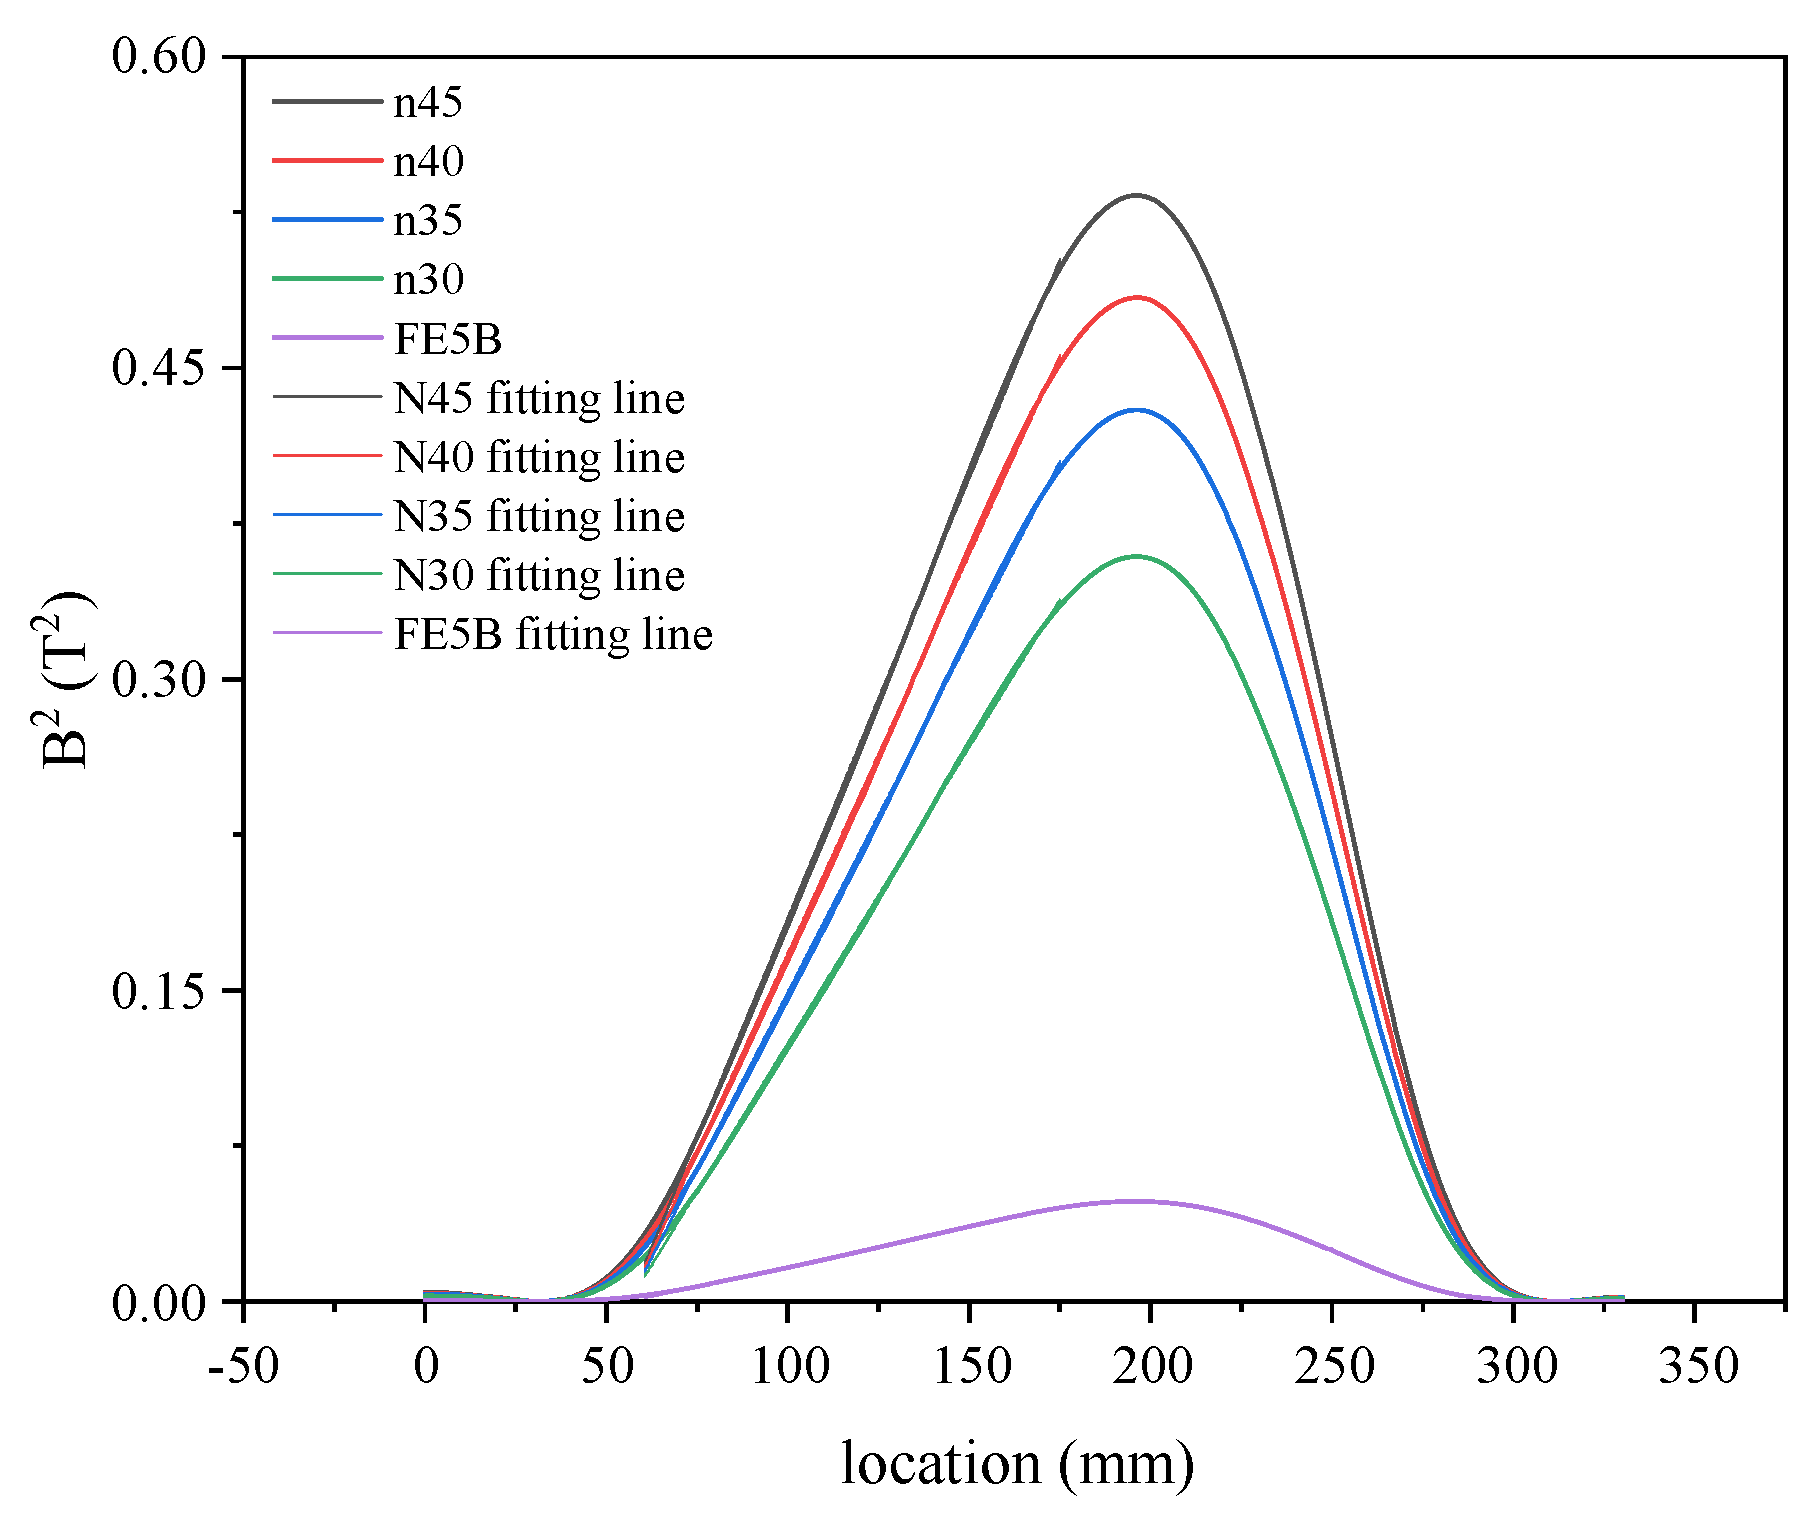
Under the fixed geometric configuration of the curved pole heads and completely identical structural parameters, boundary conditions and operational parameters consistent with the previous single-factor analysis, Figure 14 presents the spatial distribution curves of squared magnetic flux density (B2) versus the spatial coordinate along the interpolar central axis, together with their corresponding linear regression fitting results, for all tested permanent magnet materials, with the detailed fitting parameters summarized in Table 5.
The experimental and numerical simulation results indicate that the coefficient of determination (R2) for the linear regression fits of B2 versus spatial position curves within the separation zone consistently exceeds 0.999, regardless of variations in the type and grade of the permanent magnet material. This finding verifies the effective establishment of the target isodynamic magnetic field across all tested magnetic system configurations.
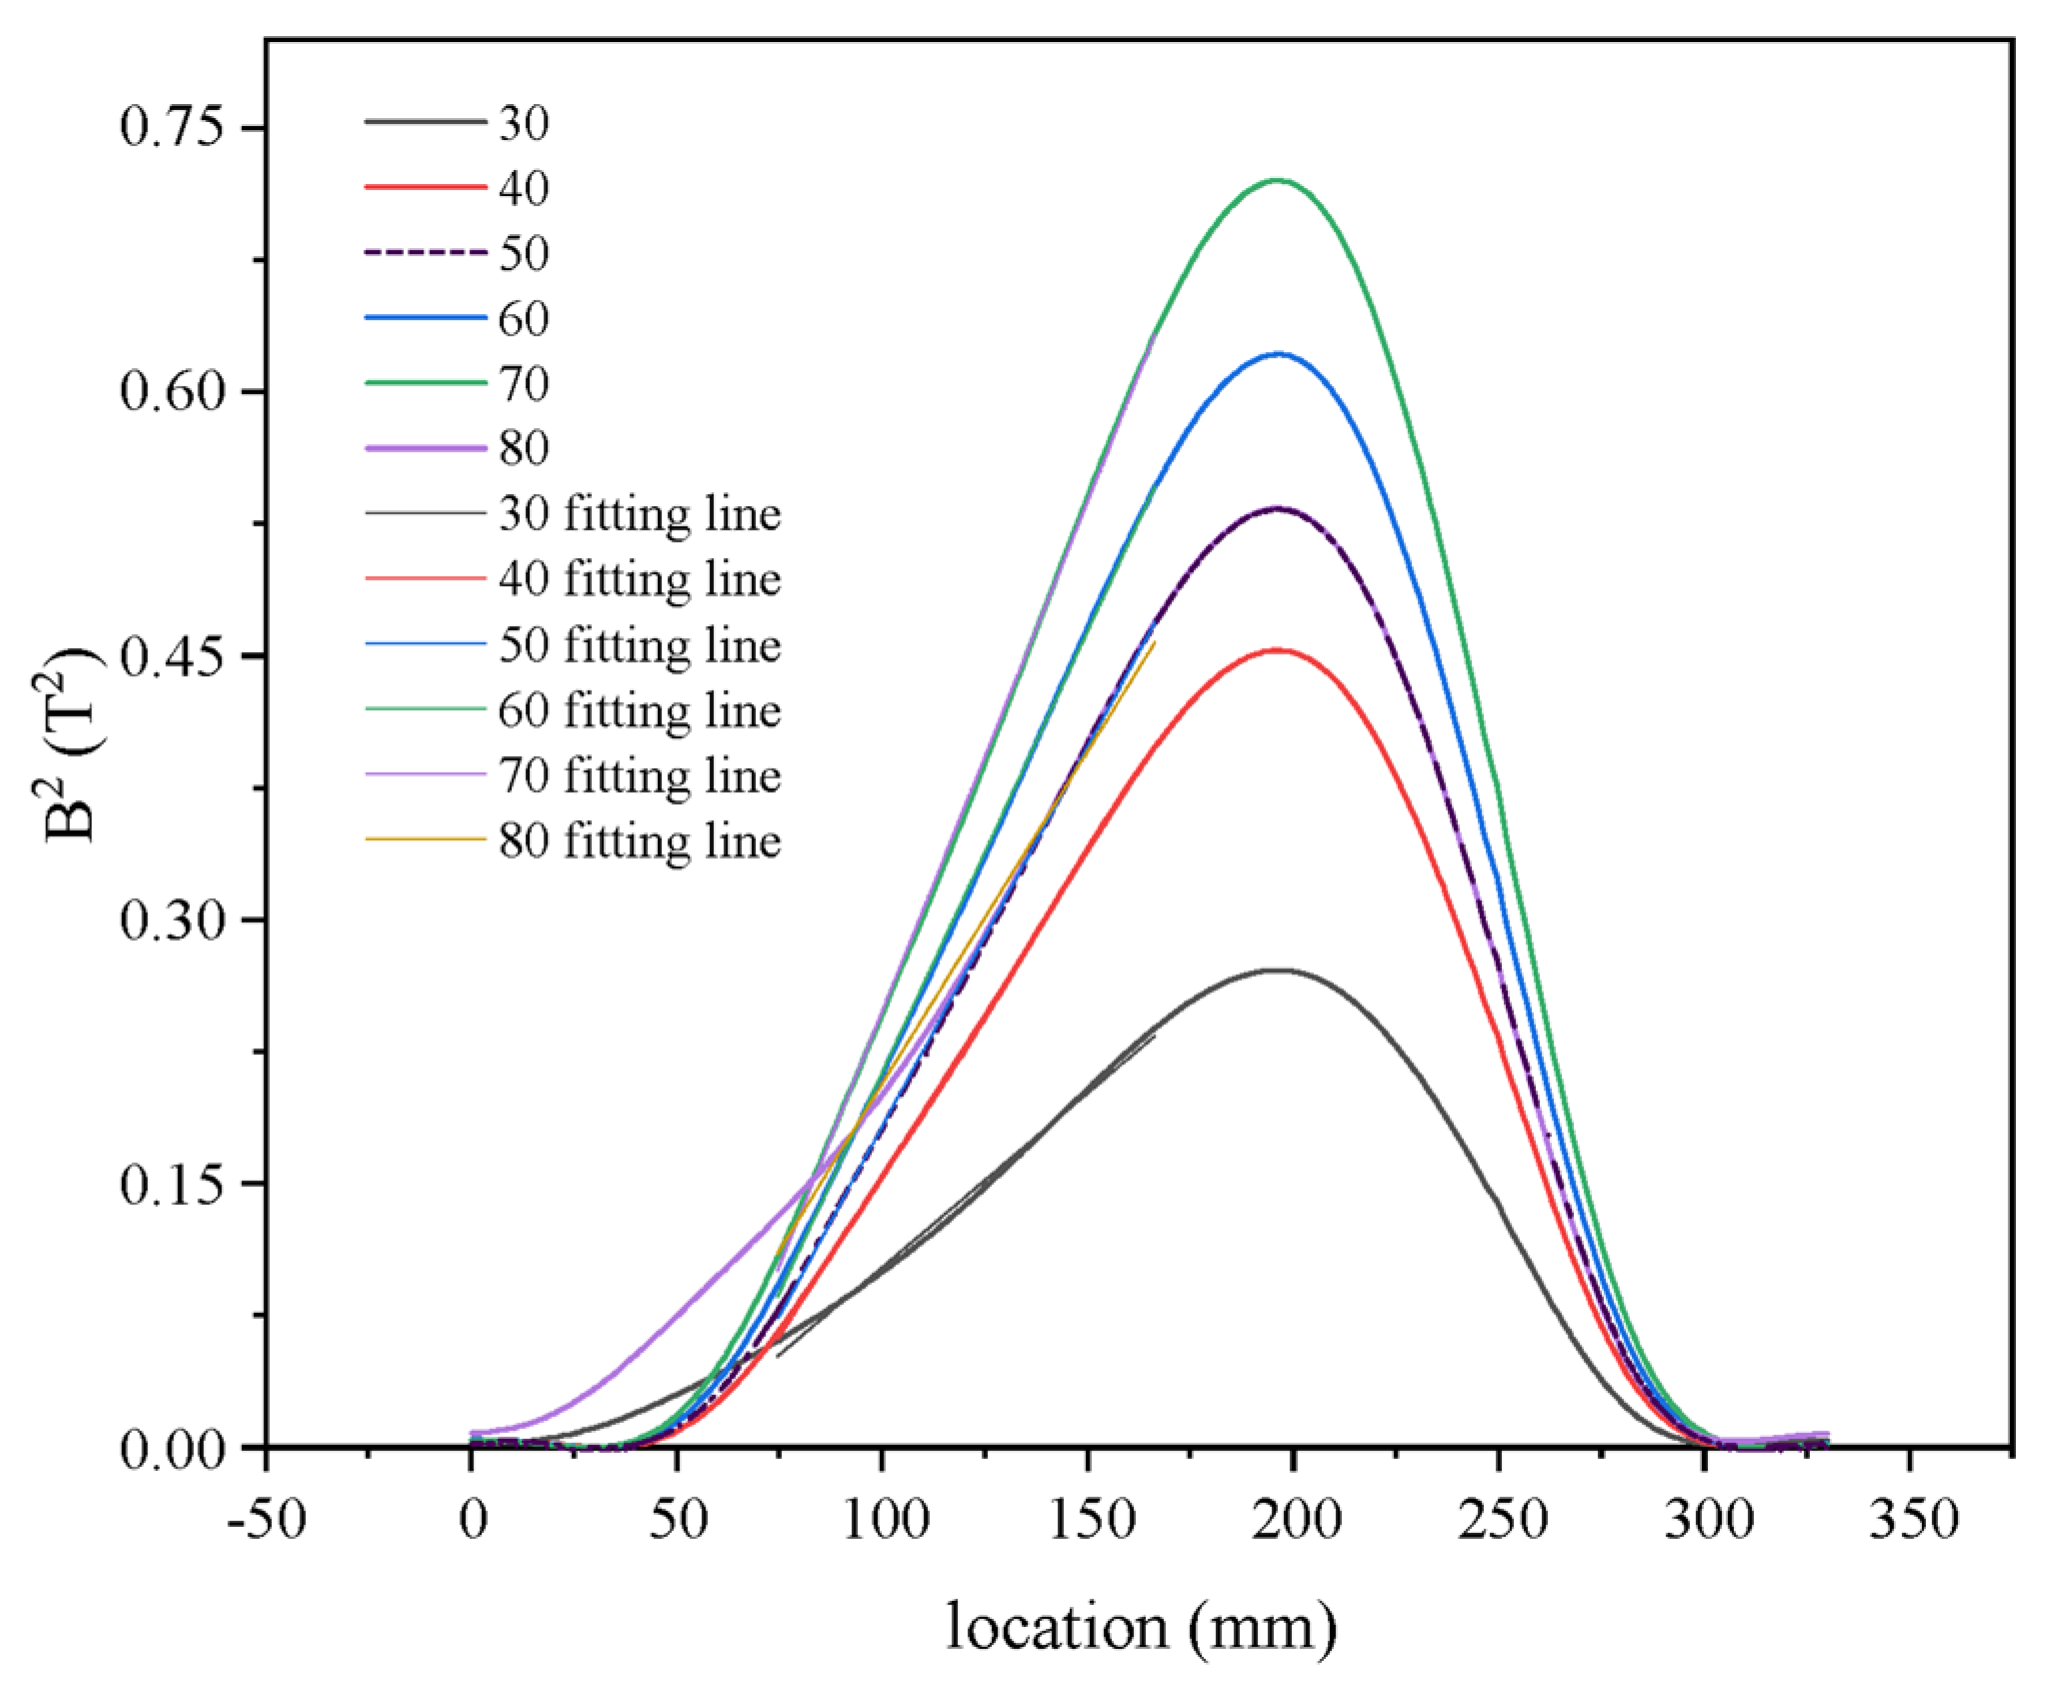
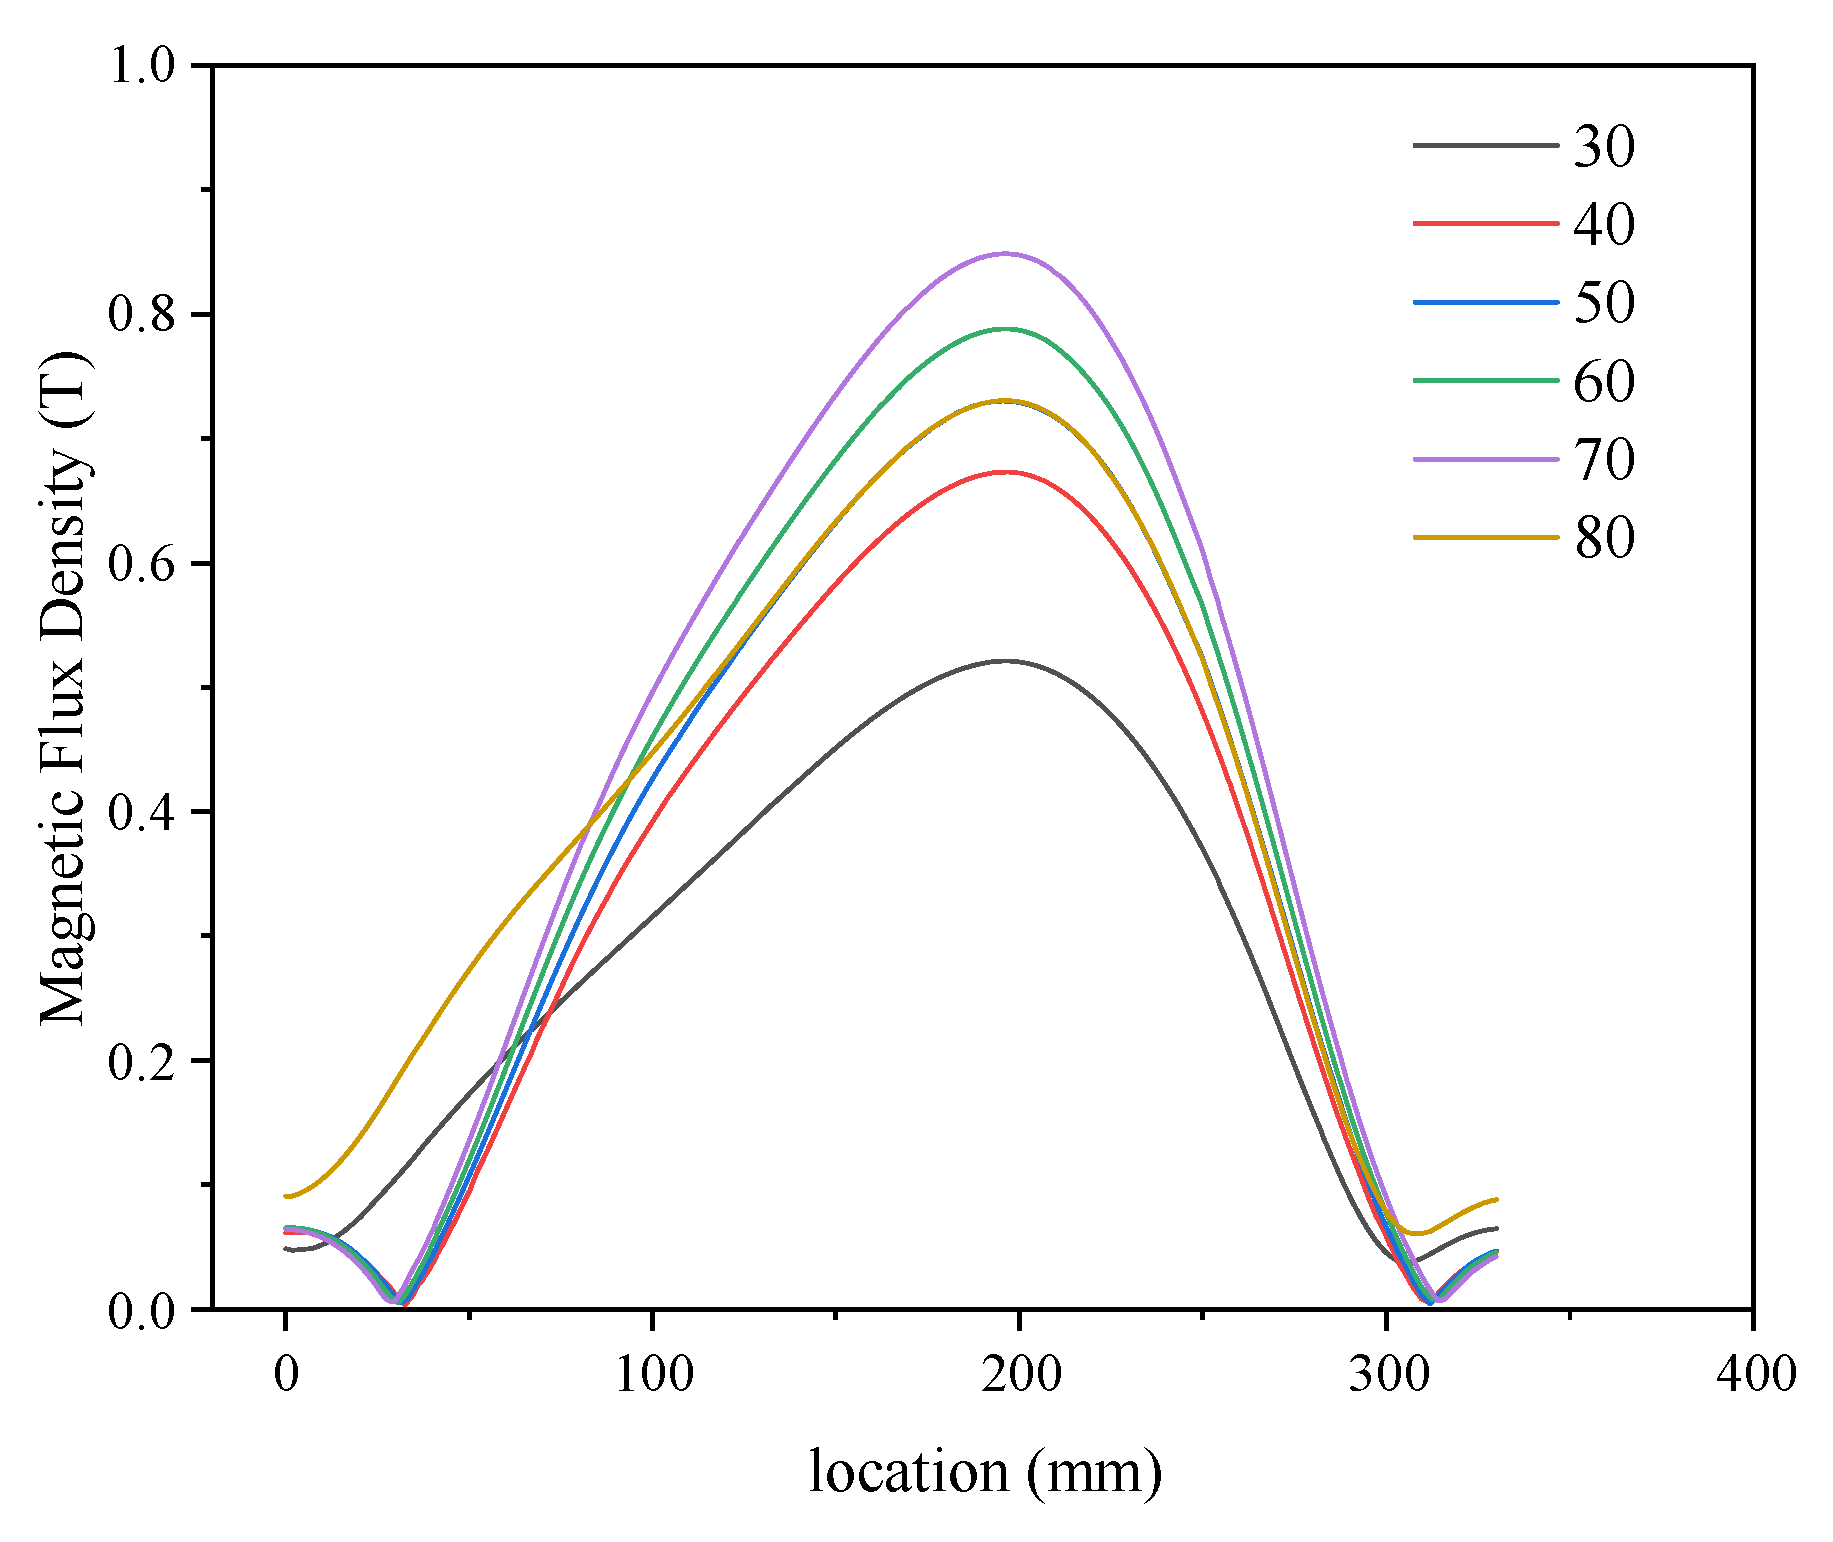
To implement the geometric optimization of the isodynamic magnetic system and investigate the influence of permanent magnet arrangement parameters on magnetic field characteristics, the length of the bilateral permanent magnet segments assembled adjacent to the back of the curved pole heads was systematically adjusted, consistent with the single-factor controlled variable analysis methodology established in the previous sections of this study. All other structural parameters, boundary conditions and operational parameters were kept completely unchanged during the analysis. Numerical simulations were systematically conducted for the bilateral permanent magnet segment lengths in the range of 30 mm to 80 mm, to quantitatively evaluate the magnetic field strength and magnetic force field uniformity in the separation zone under different magnetic system configurations.
As revealed in Figure 15, adjusting the configuration of the permanent magnet blocks surrounding the curved pole heads results in a non-monotonic relationship between the length of the bilateral permanent magnet segments and the magnetic flux density (B) at the interpolar central axis, which displays an initial increase followed by a subsequent decrease. Concurrently, the peripheral magnetic field strength in the separation zone exhibits a continuous and progressive increase with the extension of the bilateral permanent magnet segments. These observations collectively confirm an inverse correlation between the magnetic field strength and the distance from the apex of the curved pole heads, which is characterized by typical asymmetric decay profiles: a gradual decrease along the −x direction of the central axis, versus an abrupt decrease along the +x direction. Notably, the elongation of the bilateral permanent magnet segments reduces the decay rate of the magnetic field strength on both sides of the central axis.
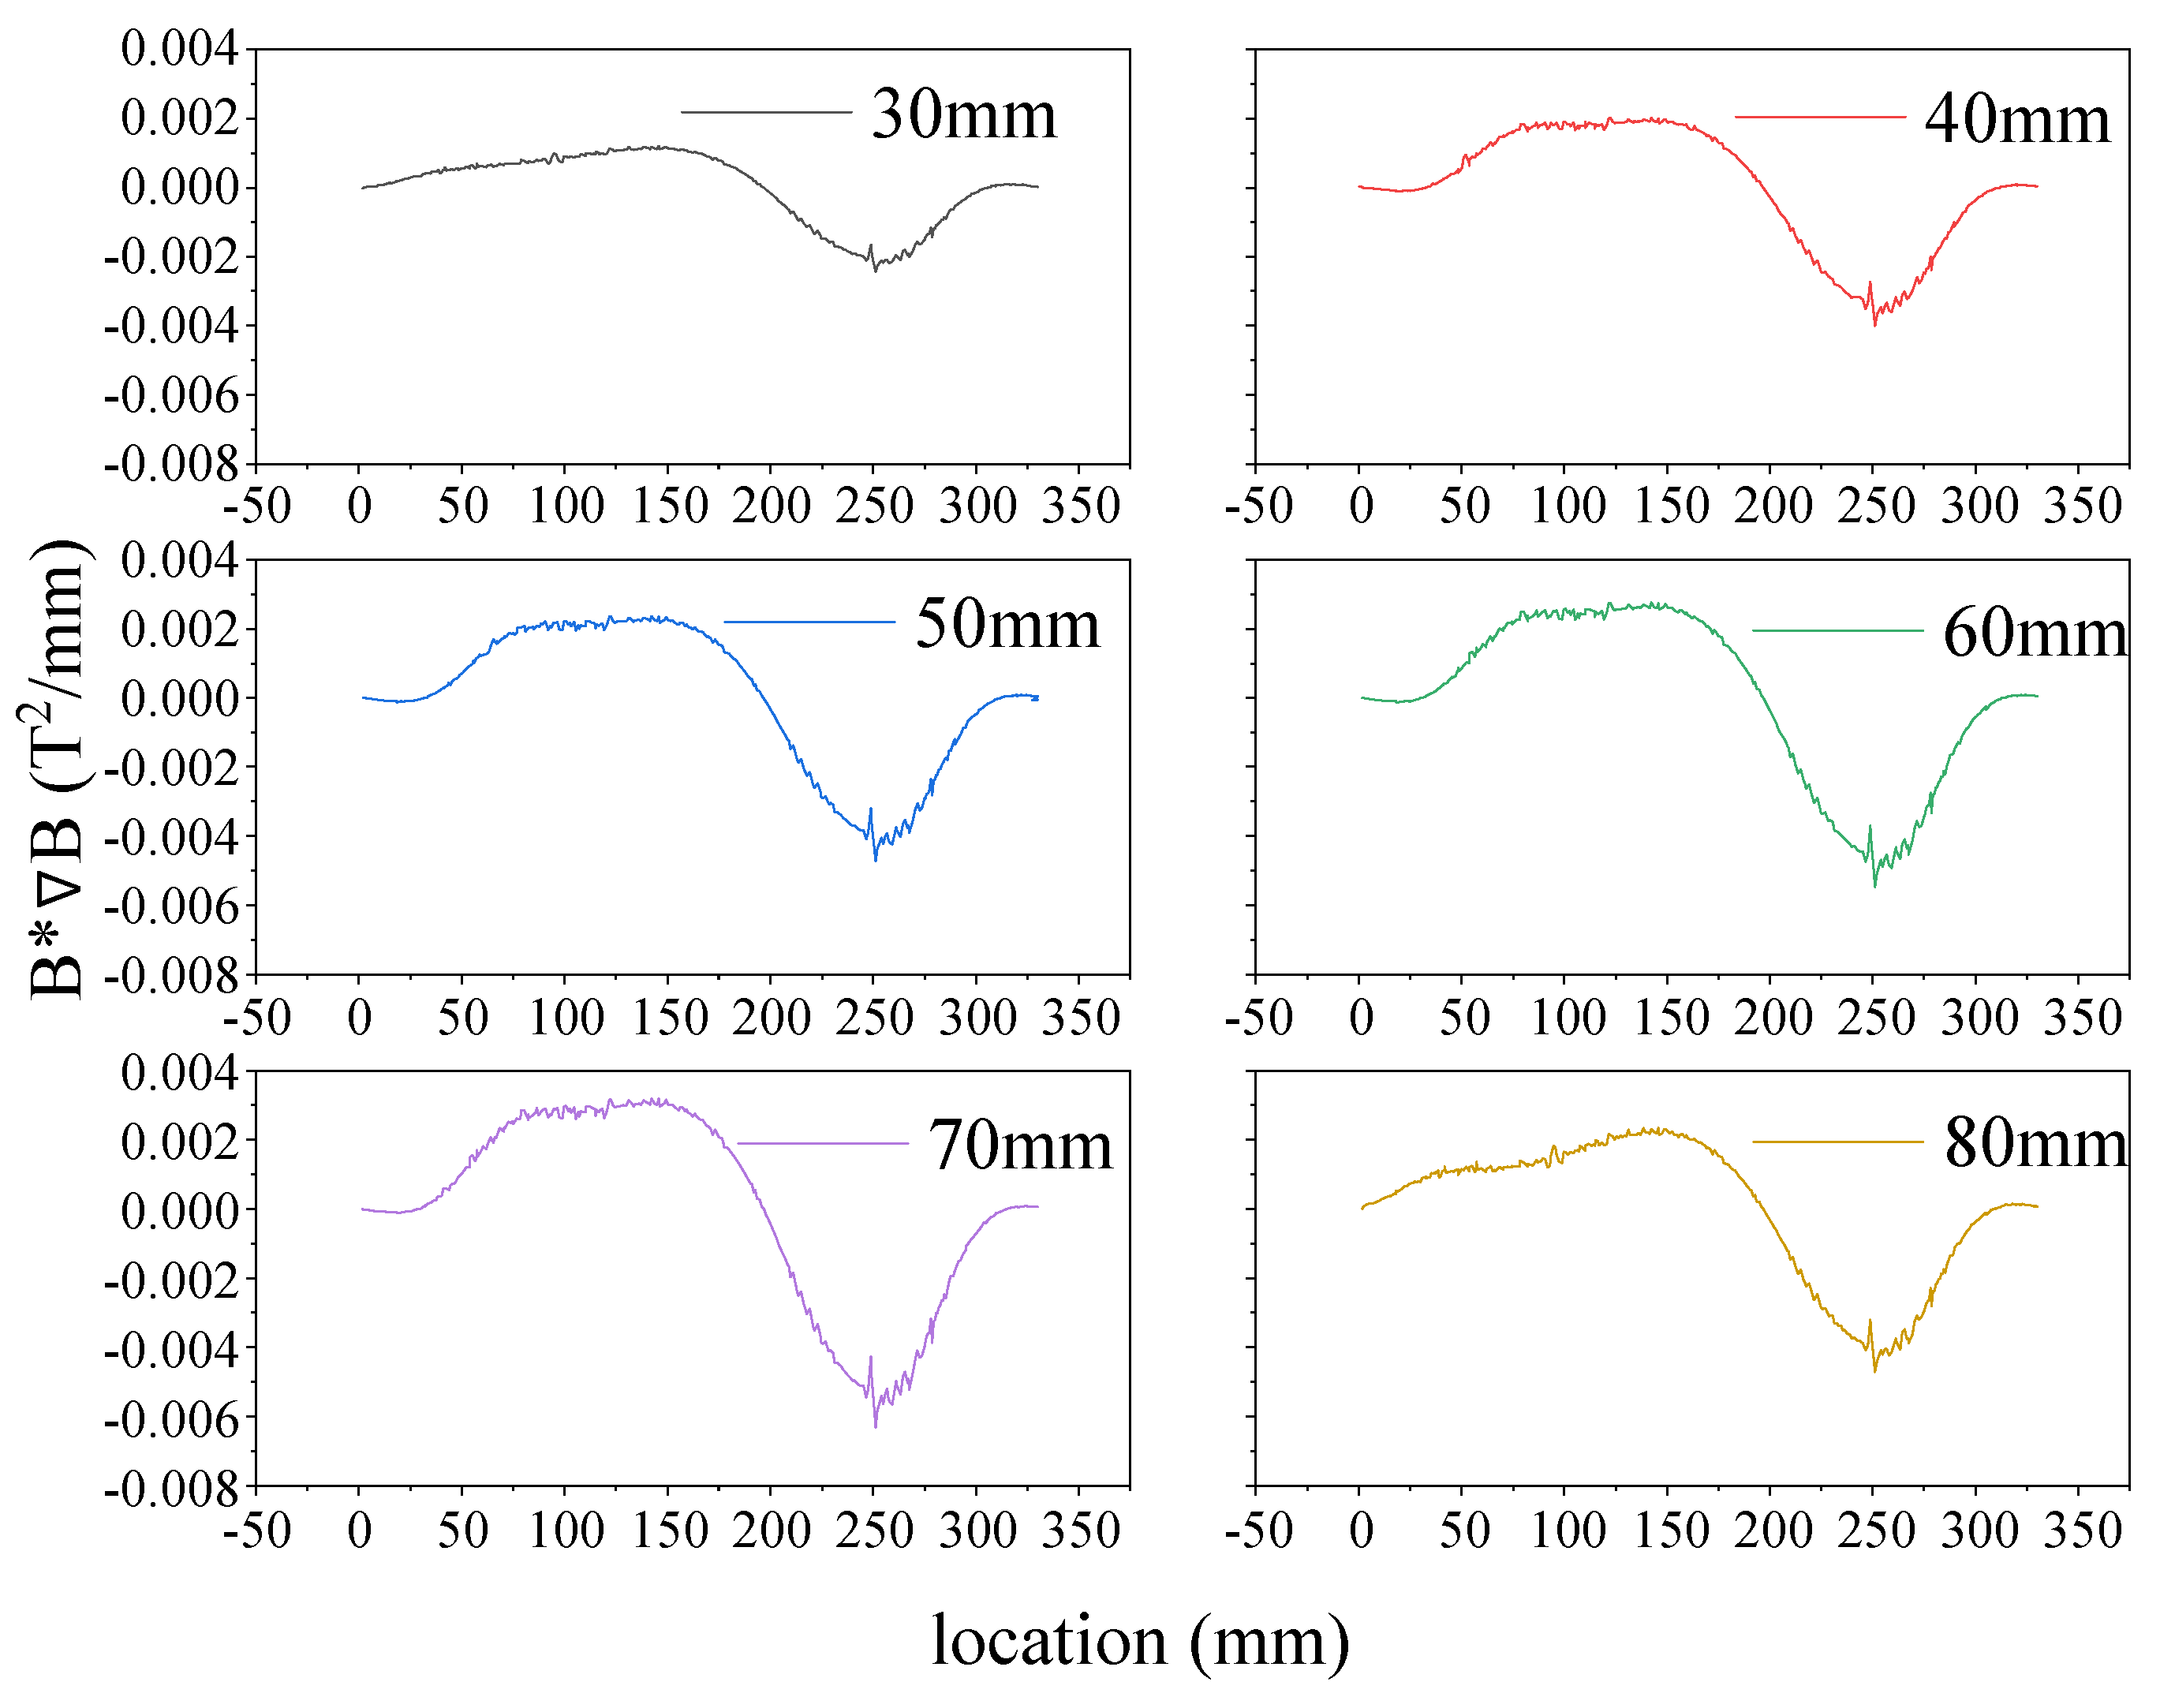
Complementary numerical analysis presents the calculated force parameter (B·∇B)—for various configurations of the bilateral permanent magnet segments, as depicted in the corresponding Figure 16.
Figure 16 demonstrates that a uniform magnetic field can be established in the separation zone only when the length of the bilateral permanent magnet segments is 40–70 mm. Any deviation from this optimal length range, whether increasing to 80 mm or decreasing to 30 mm, compromises the magnetic field uniformity and precludes the formation of an isodynamic magnetic field in the separation zone. Under the aforementioned identical control conditions, the characteristic distribution profiles of squared magnetic flux density (B2) versus spatial position, together with their corresponding linear regression fitting results for various bilateral permanent magnet segment configurations, are presented in Figure 17. The detailed parameters of these linear fits for varying bilateral magnet lengths are summarized in Table 6.
As revealed in Figure 17, when the length of the bilateral permanent magnet segments adjacent to the curved pole heads is within the range of 40 mm to 70 mm, the coefficient of determination (R2) for the linear regression fits of the squared magnetic flux density (B2) spatial profiles in the separation zone consistently exceeds 0.999, which verifies the effective establishment of the target isodynamic magnetic field (constant magnetostatic force field). Beyond this optimal range (below 40 mm or above 70 mm), the R2 values drop below the 0.999 threshold, signifying the failure to maintain the required uniform magnetic force field conditions.

4.2. Influence of Magnetic System Gap on Magnetic Field Characteristics

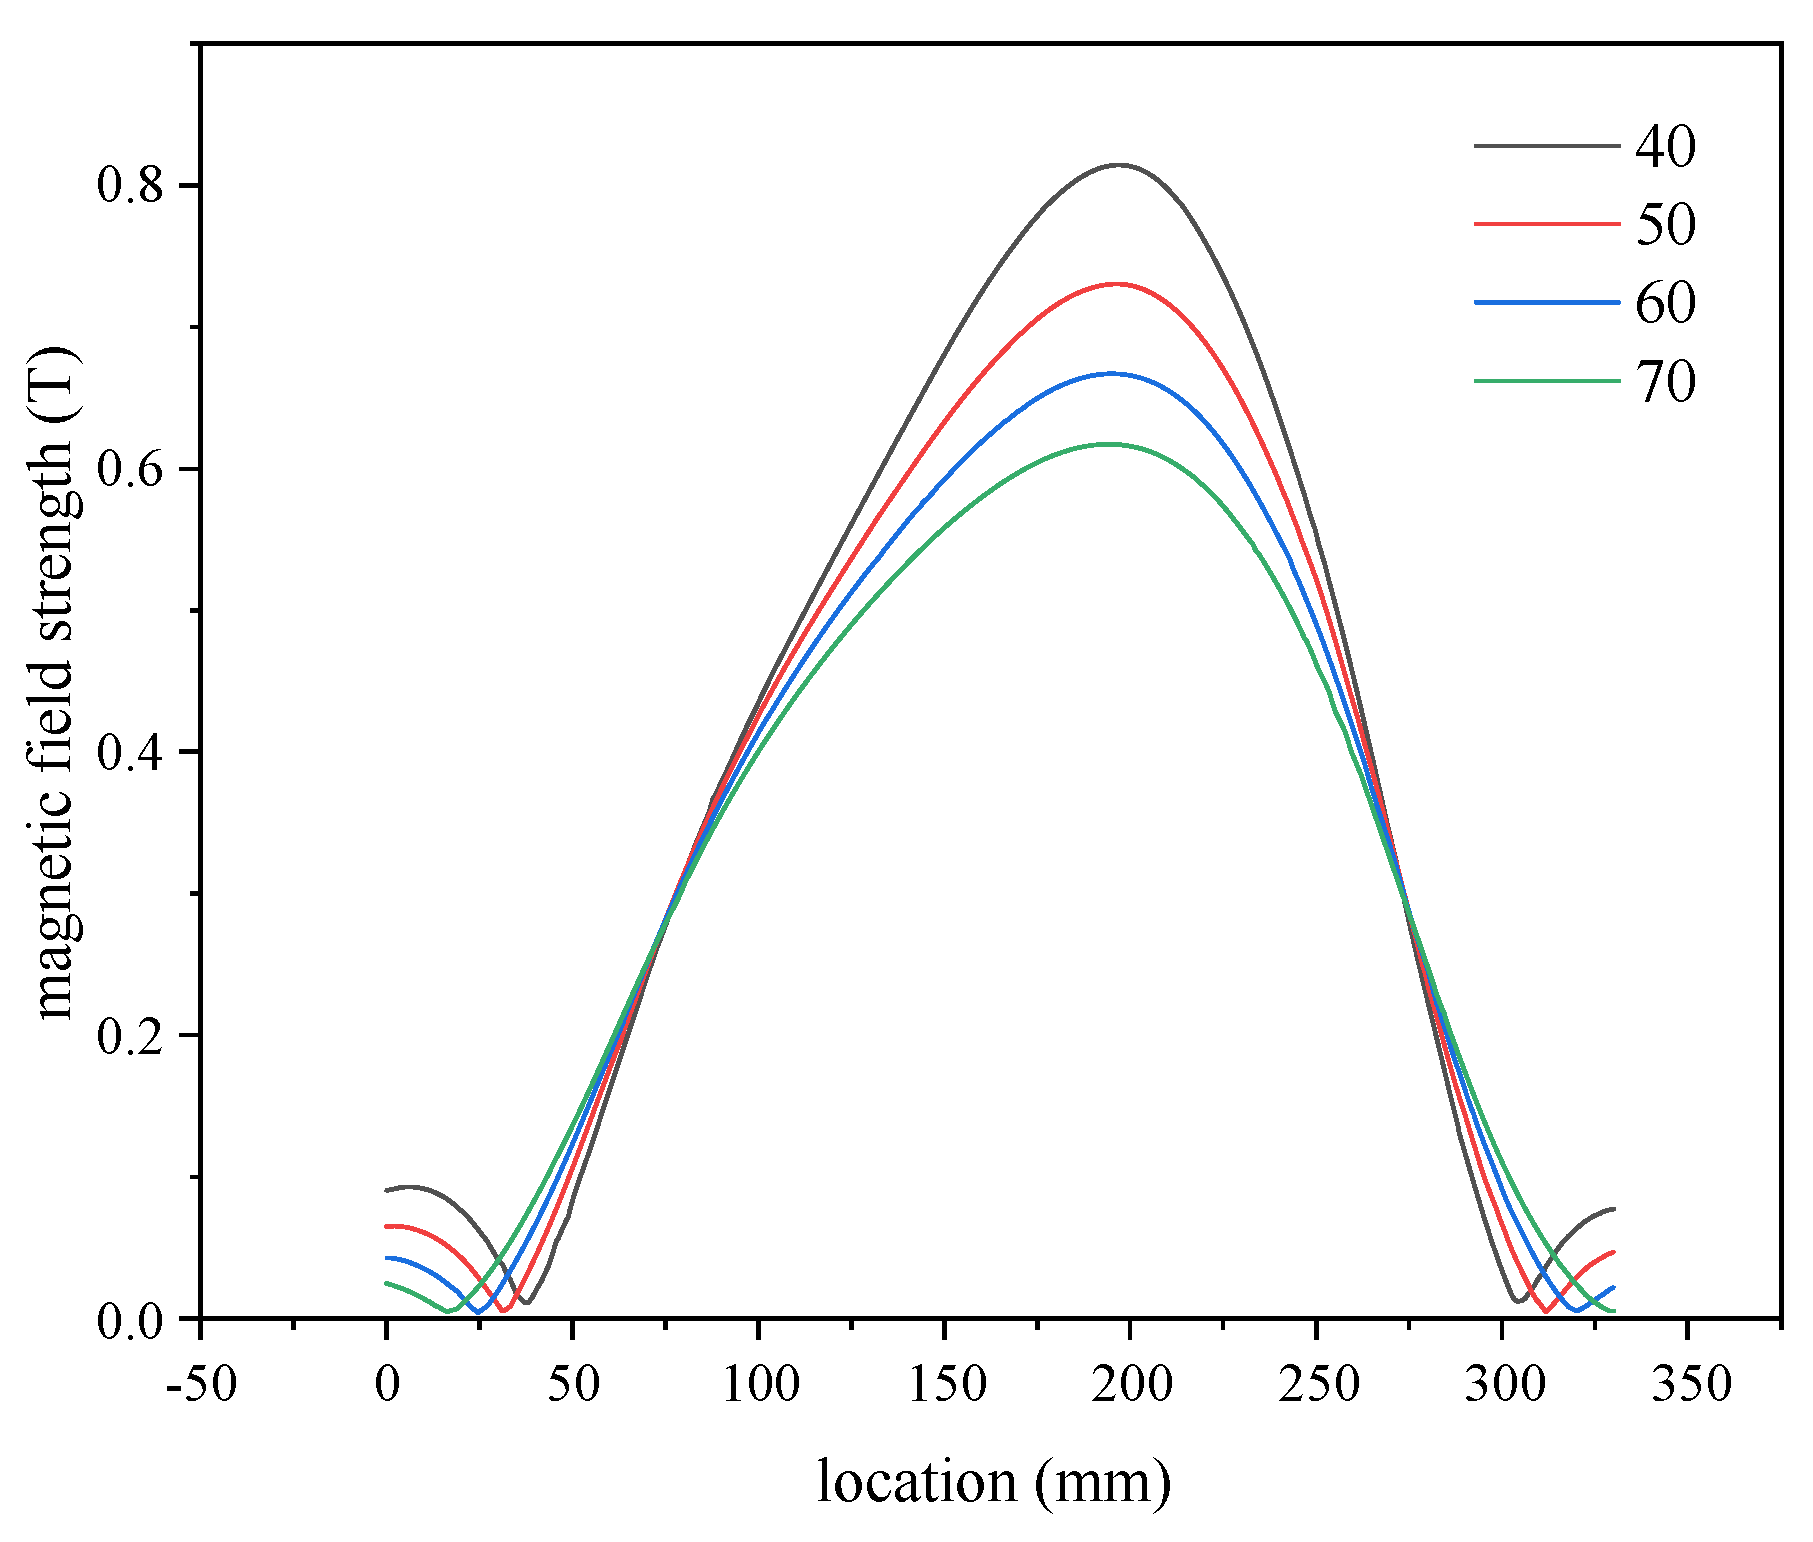
The isodynamic magnetic pole configuration adopted in this study consists of two opposed curved pole-head plates, which form a closed magnetic circuit. The interpolar gap width is a critical parameter that dominates both the magnitude and spatial distribution of the magnetic field in the separation zone. Under fixed external operational parameters and boundary conditions, numerical simulations were carried out to systematically evaluate the influence of the interpolar gap on the performance of the isodynamic magnetic system, with a specific focus on the configuration with a major arc radius of 300 mm. Parametric analysis was performed with precisely controlled interpolar gaps of 40 mm, 50 mm, 60 mm and 70 mm, with all other structural and operational parameters held constant. The characteristic distribution profiles of the magnetic field strength along the interpolar central axis obtained from the analysis are presented in the subsequent graphical results.
As revealed in Figure 18, adjusting the interpolar gap width retains the inherent spatial distribution characteristics of the magnetic field strength. The generated magnetic field maintains its inherent radial non-uniformity, with the maximum magnetic field strength achieved at the apex of the curved pole heads. The magnetic field strength exhibits a distance-dependent decrease, characterized by the typical asymmetric decay profiles: a gradual decrease along the -x direction of the interpolar central axis, versus an abrupt decrease along the +x direction. Notably, reducing the interpolar gap width increases both the peak magnetic field strength along the interpolar central axis at the apex of the curved pole heads and the overall concentration degree of the magnetic field in the separation zone.
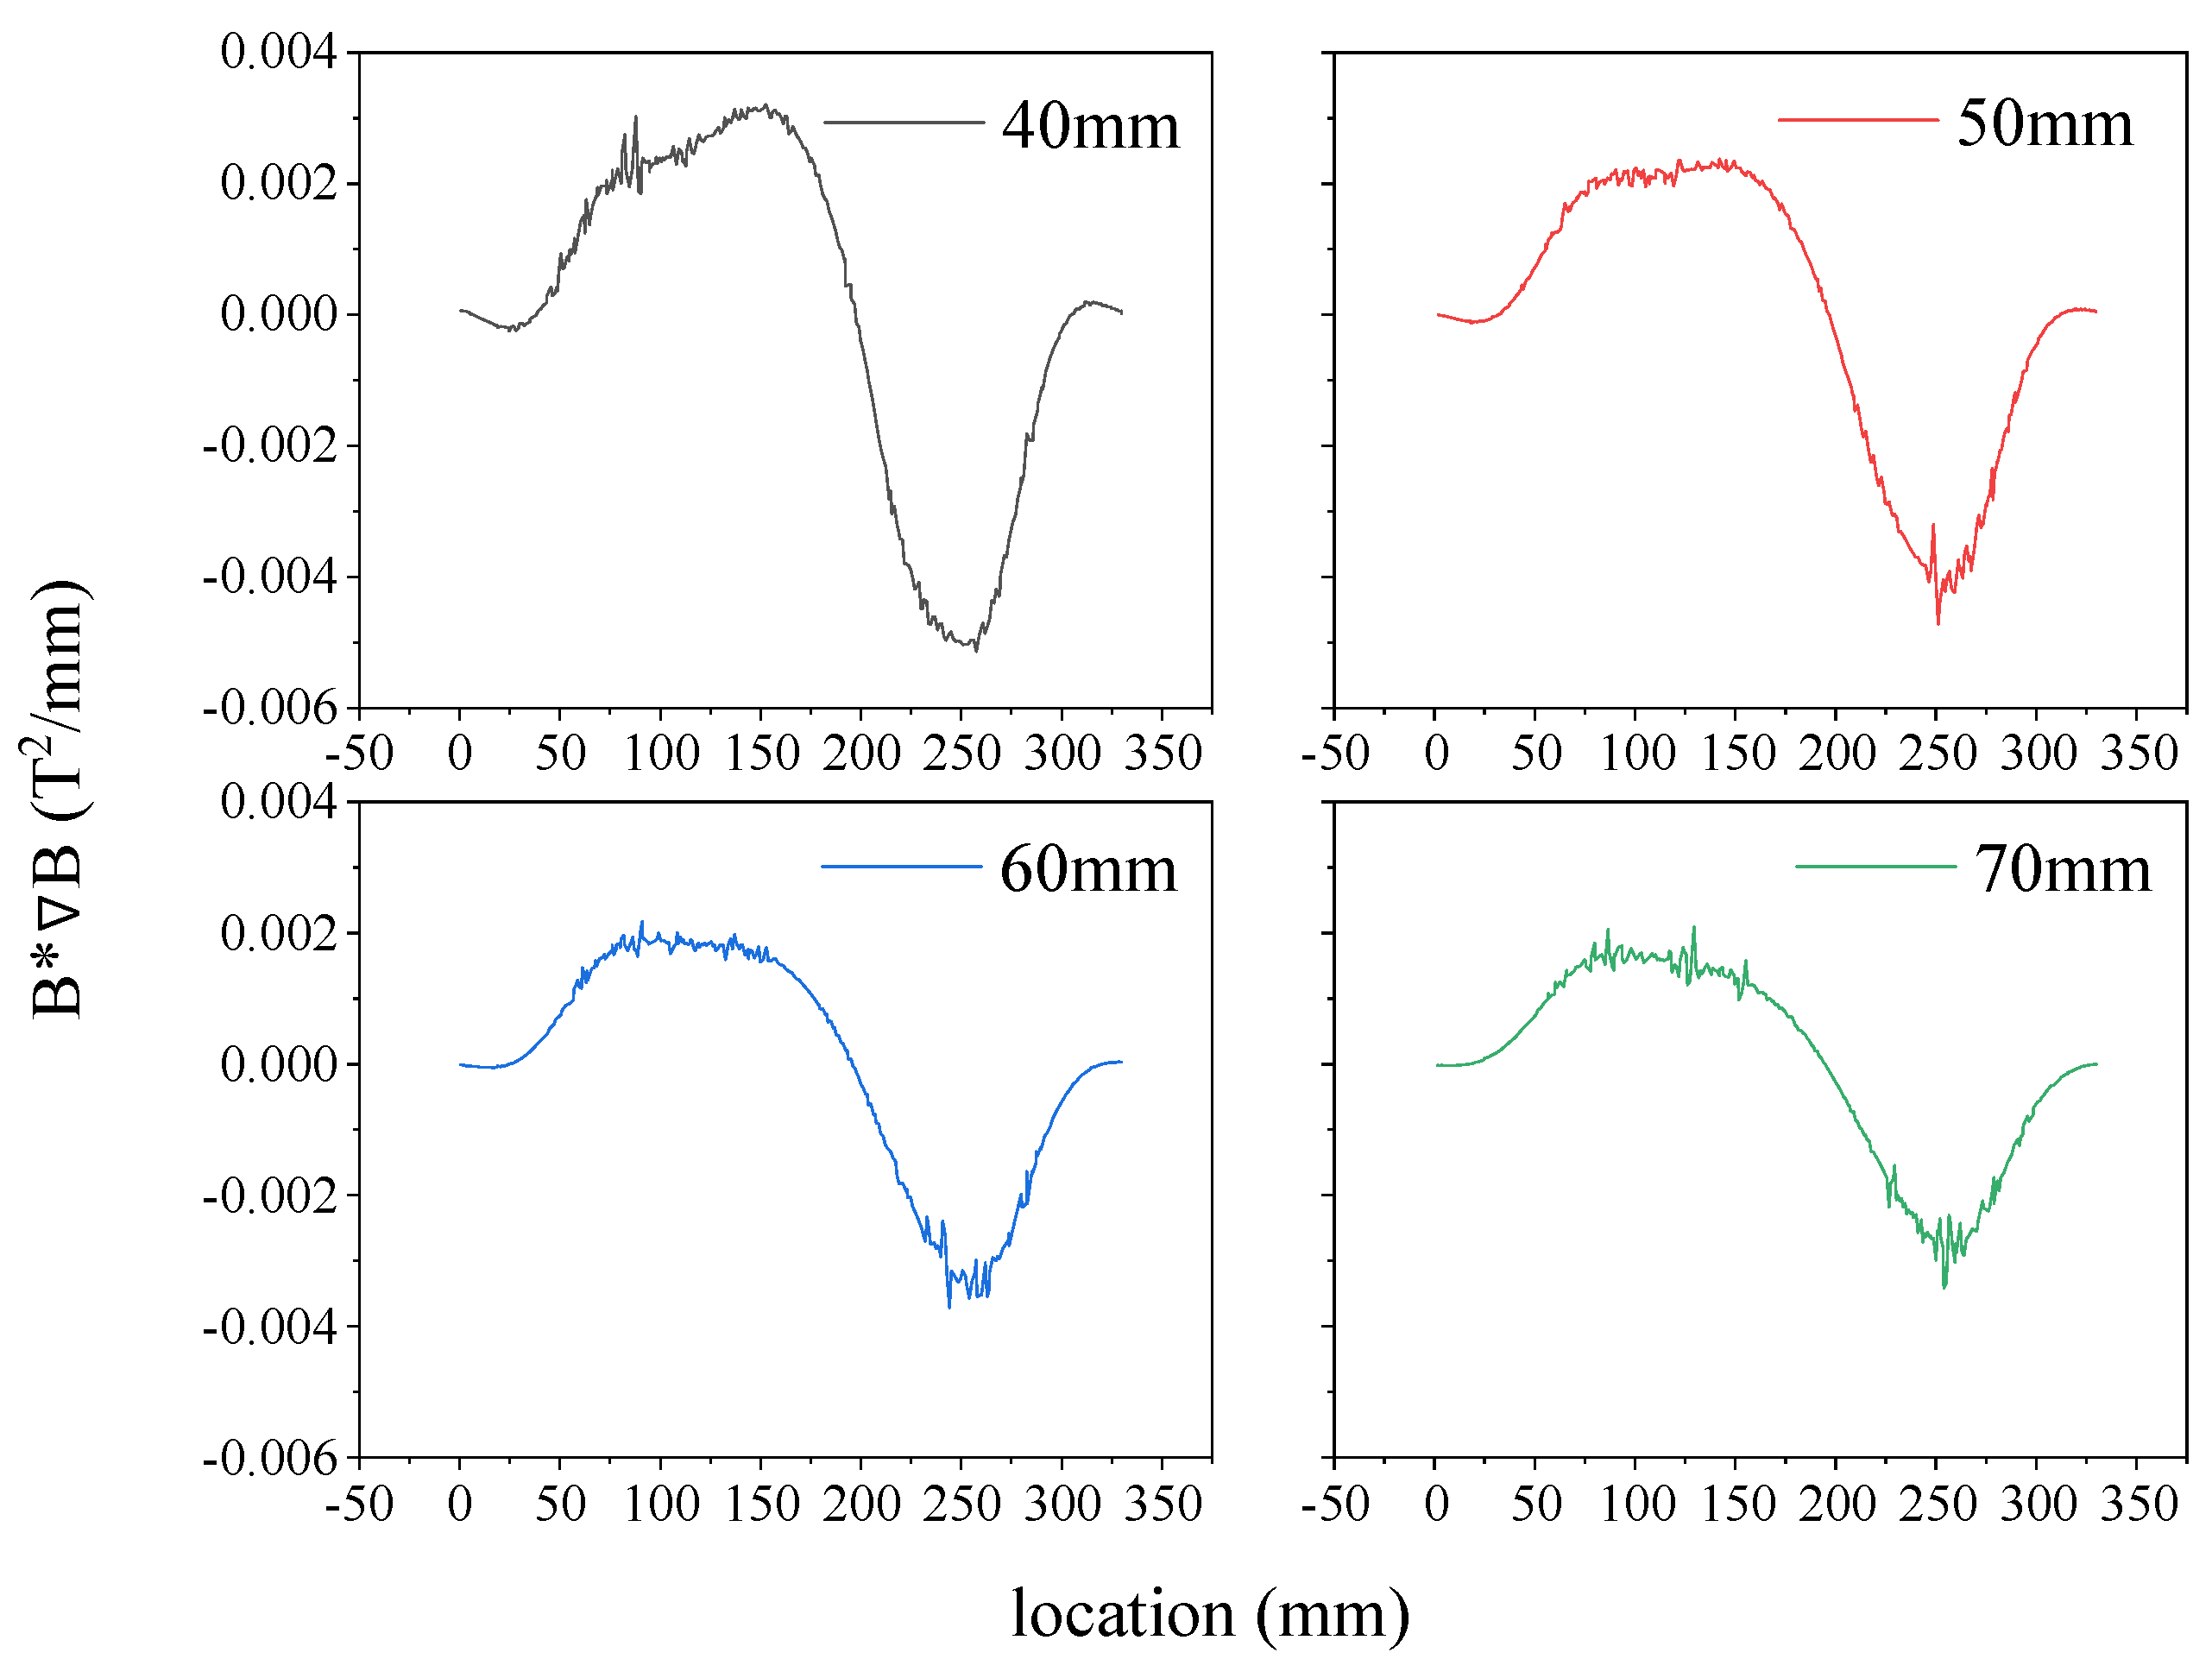
To investigate the resultant effects on the magnetostatic force exerted on the target mineral particles, the distribution curves of the force parameter (B·∇B) under different configurations of the bilateral permanent magnet segments are presented in the following plots.
As quantitatively revealed in Figure 19, the expansion of the interpolar gap width induces a systematic reduction in the magnetostatic force exerted on the target mineral particles within the separation zone, displaying a well-defined inverse proportional relationship between the interpolar gap width and the magnitude of the magnetostatic force. This correlation is a determinant of the dynamic interaction between the magnetic field and mineral particles in the separation process. Notably, the required isodynamic magnetic field conditions are only effectively established within the critical interpolar gap range of 50 mm to 60 mm, while configurations with an interpolar gap width exceeding 60 mm or below 50 mm fail to maintain such uniform isodynamic field equilibrium conditions.
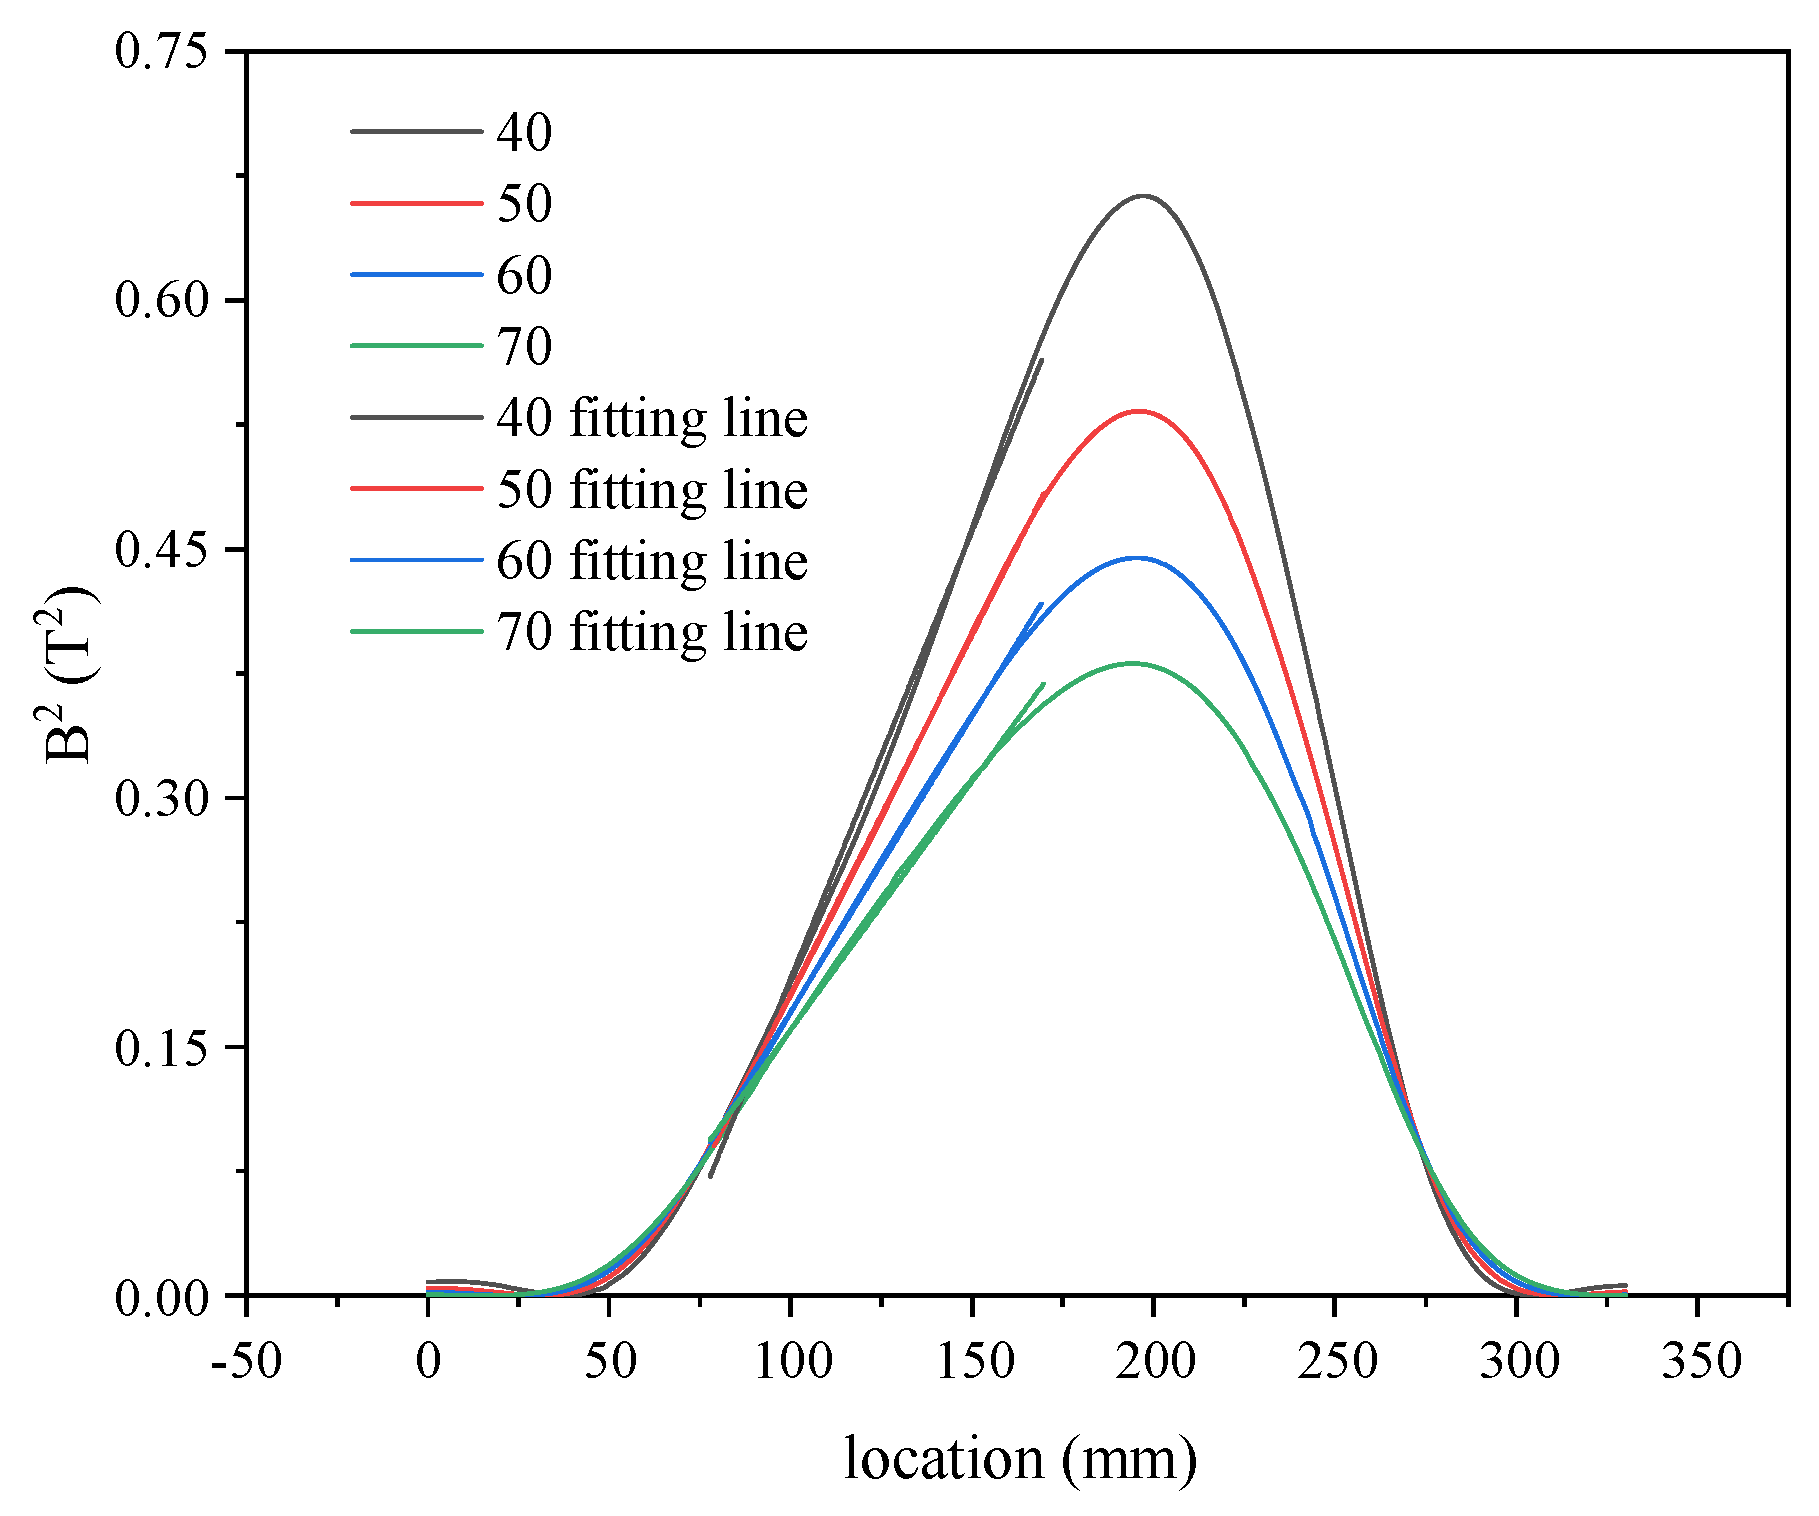
Under the aforementioned identical control conditions, Figure 20 depicts the spatial distribution profiles of squared magnetic flux density (B2) versus spatial position along the interpolar central axis, together with their corresponding linear regression fitting results, for the isodynamic magnetic systems with different interpolar gap widths. with the detailed parameters of the linear fits with varying pole spacing summarized in Table 7.
As revealed in Figure 20, within the optimal interpolar gap width range of 50 mm to 60 mm, the coefficient of determination (R2) for the linear regression fits of the squared magnetic flux density (B2) spatial profiles in the separation zone consistently exceeds 0.999, which verifies the effective establishment of a stable isodynamic (constant-force) magnetic field. Outside this optimal interpolar gap width range, the R2 values drop below this critical threshold, confirming the failure to maintain the required uniform magnetic field conditions. Furthermore, the progressive expansion of the interpolar gap width leads to a systematic decrease in both the magnetic field strength in the separation zone and the resultant magnetostatic force exerted on the target mineral particles.
5. Conclusions

A novel isodynamic magnetic system is proposed, featuring a static Halbach array configuration with no moving components or magnetic separation matrix. The key structural parameters of the magnetic system are systematically optimized via finite element numerical simulation, quantitatively revealing the influence of each parameter on the uniformity of the isodynamic magnetic field. In this study, the coefficient of determination R2 > 0.999 from the linear regression of squared magnetic flux density (B2) versus spatial position is adopted as the criterion for the uniformity of the isodynamic magnetic field, and the accuracy of the numerical simulation method is verified by comparing the numerical simulation results with the experimental measurement data.
For the permanent magnet isodynamic magnetic system adopted in this study, the systematic analysis results show that: a stable constant-force magnetic field can be constructed in the separation zone when the central angle of the curved pole head is 25°, while the uniformity requirement cannot be met when the central angle is 20° or 30°; the arc radius of the curved pole head (300 mm, 600 mm, 1200 mm) and the grade of neodymium iron boron (NdFeB) permanent magnet (N45, N40, N35, N30) only affect the magnitude of the magnetic force in the separation zone, and have no correlation with the uniformity of the constant-force magnetic field, and a stable constant-force magnetic field can be constructed under all corresponding parameters; the optimal parameter ranges are 40~70 mm for the thickness of the side-mounted magnet block of the curved pole head and 50~60 mm for the interpolar gap of the magnetic system. A uniform constant-force magnetic field can be constructed within the optimal ranges, while the magnetic field loses uniformity beyond the ranges.
The isodynamic magnetic separation method proposed in this study can effectively eliminate the non-magnetic particle entrainment caused by uneven magnetic forces and particle agglomeration. Benefiting from its unique capability of precise separation based on specific magnetic susceptibility differences, this method holds significant application prospects in the field of laboratory-scale high-precision classification of fine-grained weakly magnetic minerals, as well as in specialized scenarios requiring stringent magnetic purity control. The present work provides a theoretical foundation and numerical optimization framework to support the advancement of this technique toward practical deployment in such targeted applications.
Author Contributions

X.H.: validation, formal analysis, visualization, software, writing—review and editing. X.C.: conceptualization, methodology, writing—original draft. Y.Z.: funding acquisition; D.D.: investigation. All authors have read and agreed to the published version of the manuscript.

Funding

The authors would like to thank the financial support from the National Science and Technology Major Project of China (Grant No. 2024ZD1004001).

Data Availability Statement

The original contributions presented in this study are included in the article. Further inquiries can be directed to the corresponding author.

Conflicts of Interest

The authors declare no conflicts of interest.

References

  1. Mangani, P.; Khan, G.D.; Ahmad, N. Sustainable Governance, Conflict and Environmental Justice in Critical Mineral Extraction in Latin America and Africa. Peace Sustain. 2025, 1, 100017. [Google Scholar] [CrossRef] [Scilit]
  2. Sun, X.; Helbig, C.; Hao, H.; Watari, T.; Bhuwalka, K. Establishing resilient and sustainable supply chain of critical materials for a low-carbon future. Resour. Conserv. Recycl. 2025, 226, 108657. [Google Scholar] [CrossRef] [Scilit]
  3. Augusto, P.A.; Augusto, P.; Castelo-Grande, T. Magnetic classification. Miner. Eng. 2002, 15, 35–43. [Google Scholar] [CrossRef] [Scilit]
  4. Xie, S.; Hu, Z.; Lu, D.; Zhao, Y. Dry permanent magnetic separator: Present status and future prospects. Minerals 2022, 12, 1251. [Google Scholar] [CrossRef] [Scilit]
  5. Hu, Z.; Lu, D.; Zheng, X.; Wang, Y.; Xue, Z.; Xu, S. Development of a high-gradient magnetic separator for enhancing selective separation: A review. Powder Technol. 2023, 421, 118435. [Google Scholar] [CrossRef] [Scilit]
  6. Smolkin, M.R.; Smolkin, R.D.; Smolkin, E.R. Analysis of Magnetic Fields and Circuits in Separators With Plane-Parallel and Plane-Meridian Symmetry. IEEE Trans. Magn. 2008, 44, 1990–2001. [Google Scholar] [CrossRef] [Scilit]
  7. Goodman, A.G.; Mata, K.C.; Henneberg, S.A.; Jorge, R.; Landreman, M.; Plunk, G.G.; Smith, H.M.; Mackenbach, R.J.J.; Beidler, C.D.; Helander, P. Constructing precisely quasi-isodynamic magnetic fields. J. Plasma Phys. 2023, 89, 905890504. [Google Scholar] [CrossRef] [Scilit]
  8. Lin, D.; Leroux, M.; Finch, J.A. Batch magnetohydrostatic separations with a modified Frantz separator. Miner. Eng. 1995, 8, 283–292. [Google Scholar] [CrossRef] [Scilit]
  9. Tuisku, J.; Ahoranta, M.; Korpela, A.; Lehtonen, J.; Mikkonen, R.; Perala, R. Cryogenic design of an isodynamic magnetic separator. IEEE Trans. Appl. Supercond. 2004, 14, 1580–1583. [Google Scholar] [CrossRef]
  10. Jinnouchi, S.; Uyeda, C.; Hisayoshi, K.; Takayama, G.; Terada, K. New development of compact magnetic separator for on-site material screening in various geological survey. J. Anal. Sci. Technol. 2024, 15, 12. [Google Scholar] [CrossRef] [Scilit]
  11. Lindner, J.; Menzel, K.; Nirschl, H. Simulation of magnetic suspensions for HGMS using CFD, FEM and DEM modeling. Comput. Chem. Eng. 2013, 54, 111–121. [Google Scholar] [CrossRef] [Scilit]
  12. Mohanty, S.; Das, B.; Mishra, B.K. A preliminary investigation into magnetic separation process using CFD. Miner. Eng. 2011, 24, 1651–1657. [Google Scholar] [CrossRef] [Scilit]
  13. Li, W.; Han, Y.; Xu, R.; Gong, E. A preliminary investigation into separating performance and magnetic field characteristic analysis based on a novel matrix. Minerals 2018, 8, 94. [Google Scholar] [CrossRef] [Scilit]
  14. Zheng, X.; Guo, N.; Cui, R.; Lu, D.; Li, X.; Li, M.; Wang, Y. Magnetic field simulation and experimental tests of special cross-sectional shape matrices for high gradient magnetic separation. IEEE Trans. Magn. 2017, 53, 1–10. [Google Scholar] [CrossRef] [Scilit]
  15. Hafner, M.; Schöning, M.; Antczak, M.; Demenko, A.; Hameyer, K. Methods for computation and visualization of magnetic flux lines in 3-D. IEEE Trans. Magn. 2010, 46, 3349–3352. [Google Scholar] [CrossRef] [Scilit]
  16. Baik, S.K.; Ha, D.W.; Ko, R.K.; Kwon, J.M. Magnetic field and gradient analysis around matrix for HGMS. Phys. C Supercond. Its Appl. 2010, 470, 1831–1836. [Google Scholar] [CrossRef] [Scilit]
  17. Wu, L.; Tang, D.; Wen, J.; Gong, M.; Wang, F.; Dai, H. Advancements and applications of numerical simulation in enhancing the efficiency of low-intensity magnetic separators. Miner. Eng. 2025, 234, 109750. [Google Scholar] [CrossRef] [Scilit]
  18. Li, W.; Zhou, L.; Han, Y.; Xu, R. Numerical simulation and experimental verification for magnetic field analysis of thread magnetic matrix in high gradient magnetic separation. Powder Technol. 2019, 355, 300–308. [Google Scholar] [CrossRef] [Scilit]
  19. Skopenkov, M. The boundary value problem for discrete analytic functions. Adv. Math. 2013, 240, 61–87. [Google Scholar] [CrossRef] [Scilit]
  20. Huang, T.-M.; Li, T.; Chern, R.-L.; Lin, W.-W. Electromagnetic field behavior of 3D Maxwell’s equations for chiral media. J. Comput. Phys. 2019, 379, 118–131. [Google Scholar] [CrossRef] [Scilit]
  21. Bruckner, F.; Vogler, C.; Feischl, M.; Praetorius, D.; Bergmair, B.; Huber, T.; Fuger, M.; Suess, D. 3D FEM–BEM-coupling method to solve magnetostatic Maxwell equations. J. Magn. Magn. Mater. 2012, 324, 1862–1866. [Google Scholar] [CrossRef] [Scilit]
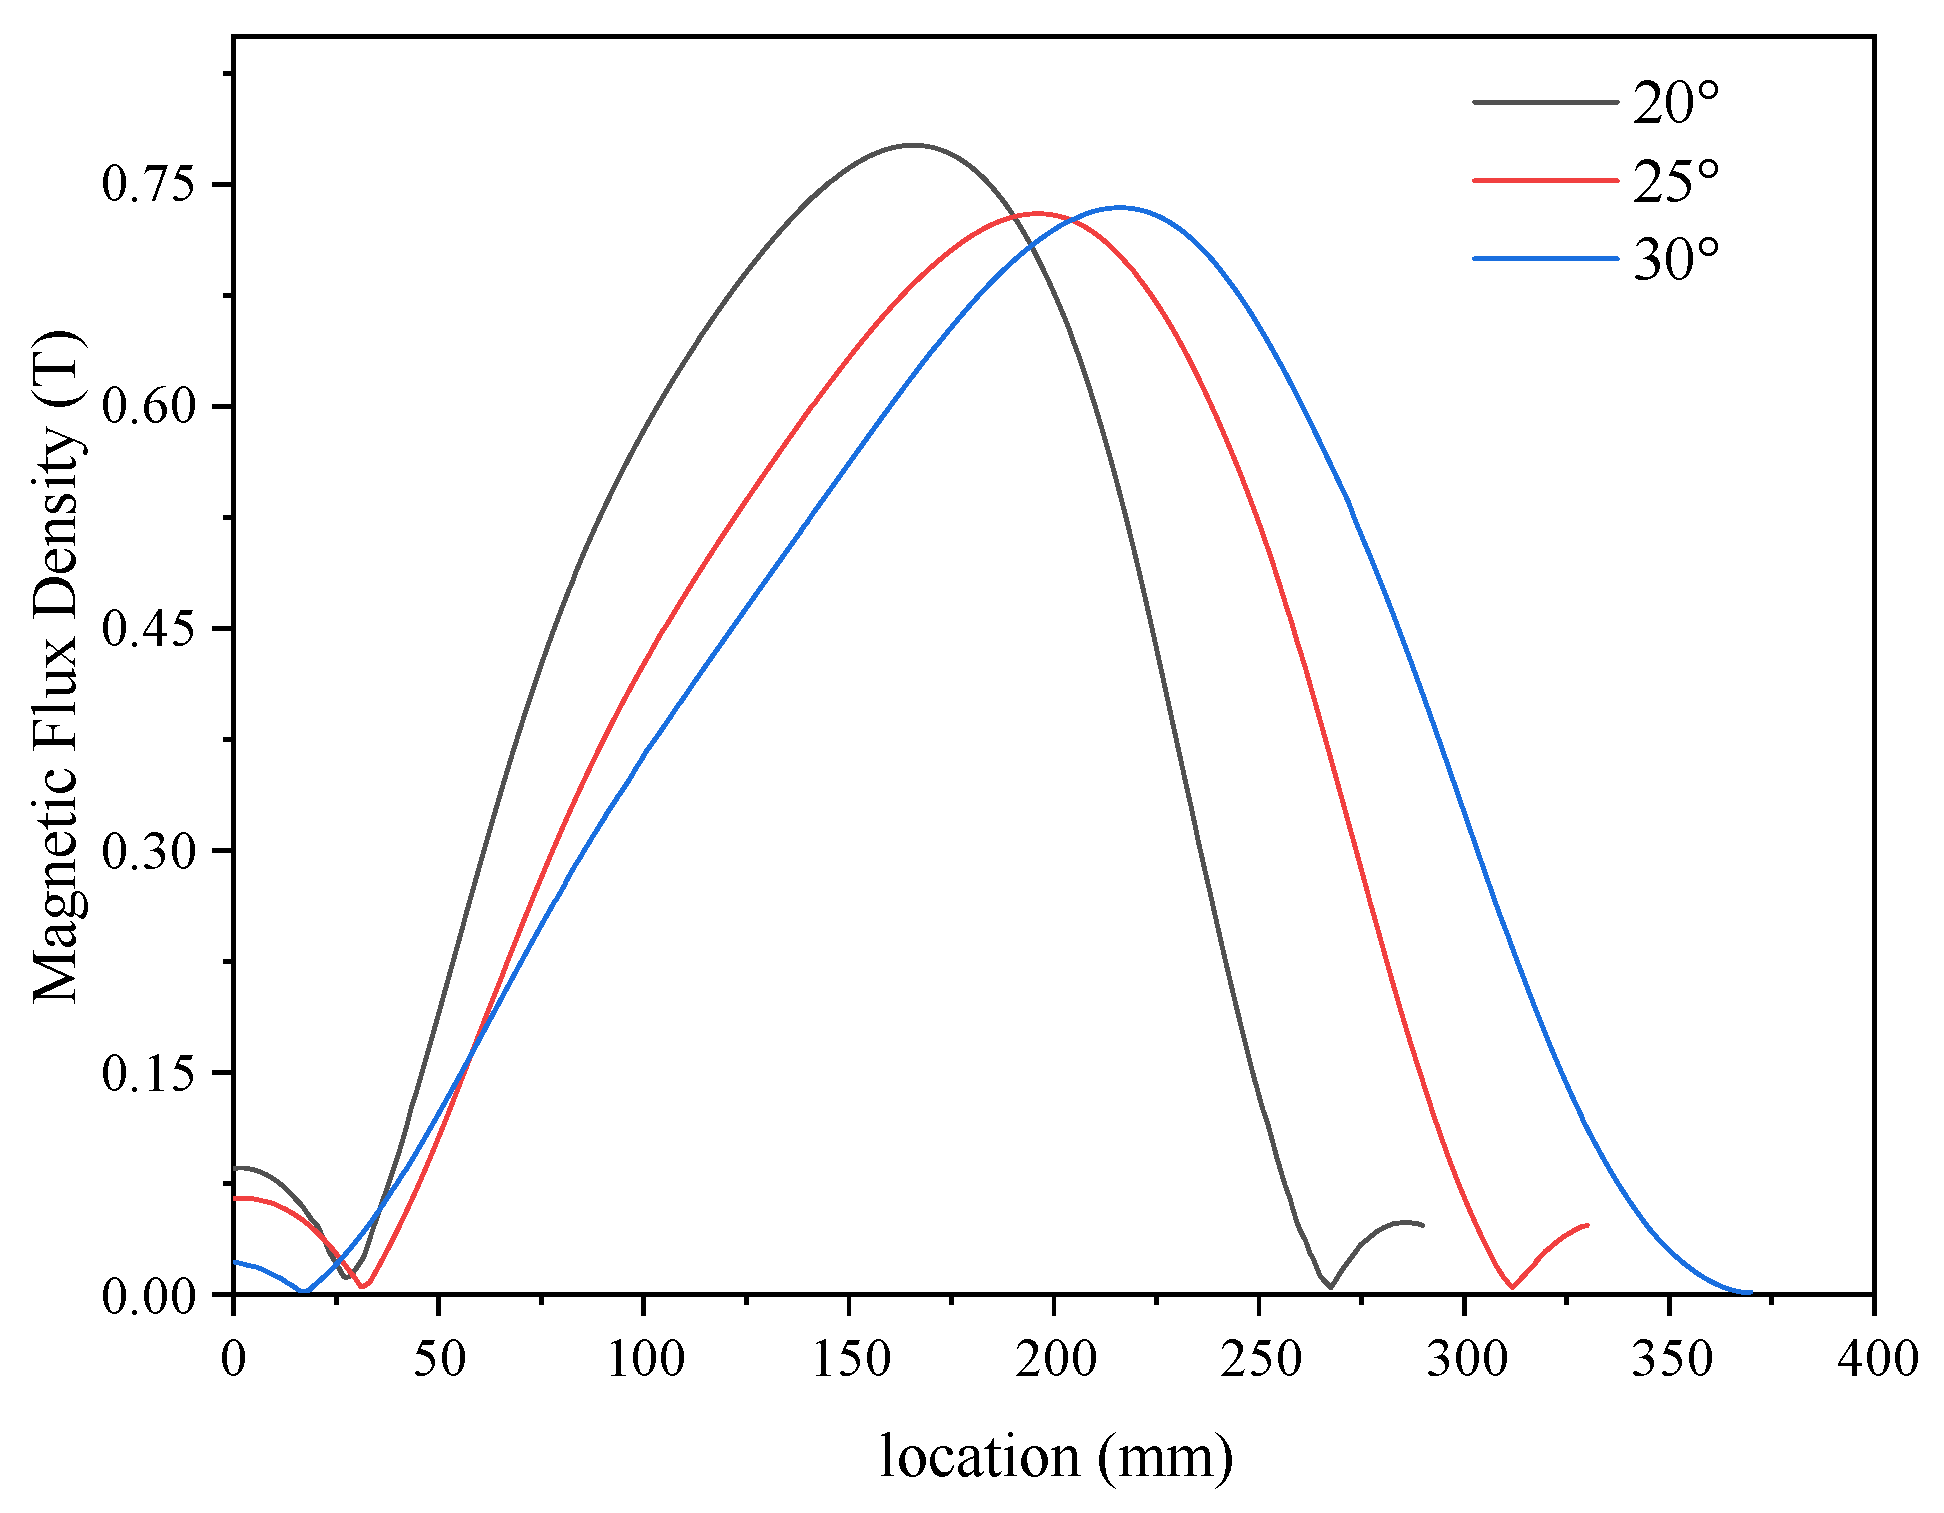
Figure 1. Schematic diagram of the magnetic system configuration and the magnetic forces on particles.
Minerals 16 00761 g001
Figure 2. BH hysteresis curve of measured N45-grade NdFeB permanent magnet.
Minerals 16 00761 g002
Figure 3. Schematic diagram of the grid.
Minerals 16 00761 g003
Figure 4. Contour map of magnetic field intensity in the simulation domain.
Minerals 16 00761 g004
Figure 5. Comparison of magnetic field intensity between simulation and experimental results.
Minerals 16 00761 g005
Figure 6. Variations in magnetic field parameters along the axial centerline at 20–30° magnetic pole tip central angle.
Minerals 16 00761 g006
Figure 7. Variations in product of magnetic flux density and gradient along the axial centreline at 20–30° magnetic pole tip central angle.
Minerals 16 00761 g007
Figure 8. Variations in square of magnetic flux density (B2) along the axial centerline at 20–30° magnetic pole tip central angle and corresponding linear fit.
Minerals 16 00761 g008
Figure 9. Variations in magnetic field parameters along the axial centerline at 300–1200 mm pole tip size.
Minerals 16 00761 g009
Figure 10. Variations in product of magnetic flux density and gradient of the axial centerline at 300–1200 mm pole tip size.
Minerals 16 00761 g010
Figure 11. Variations in square of magnetic flux density (B2) along the axial centerline at 300–1200 mm pole tip size and corresponding linear fit.
Minerals 16 00761 g011
Figure 12. Variations in magnetic field parameters along the axial centerline for different magnet material types.
Minerals 16 00761 g012
Figure 13. Variations in the product of magnetic flux density and gradient along the axial centerline for different magnet material types.
Minerals 16 00761 g013
Figure 14. Variations in square of magnetic flux density (B2) along the axial centerline for different magnet material types and corresponding linear fit.
Minerals 16 00761 g014
Figure 15. Variations in magnetic field parameters along the axial centerline at 30–80 mm bilateral magnet length on magnetic system.
Minerals 16 00761 g015
Figure 16. Variations in the product of magnetic flux density and gradient along the axial centerline at 30–80 mm bilateral magnet length on magnetic system.
Minerals 16 00761 g016
Figure 17. Variations in square of magnetic flux density (B2) along the axial centerline at 30–80 mm bilateral magnet length on system and corresponding linear fit.
Minerals 16 00761 g017
Figure 18. Variations in magnetic field parameters along the axial centerline at 40–70 mm pole spacing on system.
Minerals 16 00761 g018
Figure 19. Variations in the product of magnetic flux density and gradient along the axial centerline at 40–70 mm pole spacing on system.
Minerals 16 00761 g019
Figure 20. Variations in square of magnetic flux density (B2) along the axial centerline at 40 mm–70 mm pole spacing on system and corresponding linear fit.
Minerals 16 00761 g020
Table 1. Simulation material settings.
CaseN PoleS PolePole PieceMedium
1FB5DFB5DS10CAIR
2N30N30S10CAIR
3N35N35S10CAIR
4N40N40S10CAIR
5N45N45S10CAIR
Table 2. Physical properties of materials in the simulation.
MaterialsBr (Gs)Hcb (KA·m−1)BHmax (KJ·m−3)
FB5D415254.632.6
N3011,000876220
N3512,000876265
N4012,800876320
N4513,500876350
Table 3. Parameters of the linear fit for B2 vs. position.
20° Fit25° Fit30° Fit
Equationy = a + b∗x
PlottingB2
Weightsunweighted
Intercept−0.25888 ± 0.00341−0.24962 ± 8.99723 × 10⁻⁴−0.28603 ± 0.00308
Slope0.00588 ± 3.4435 × 10−50.00432 ± 7.1483 × 10−60.00405 ± 2.08143 × 10⁻⁵
Residual sum of squares0.007823.57422 × 10−40.00406
Pearson’s r0.998380.999870.99857
R2 (COD)0.996750.999740.99715
Adjusted R20.996720.999740.99712
Table 4. Parameters of linear fits for B2 vs. position under different pole tip sizes.
300 Fit600 Fit1200 Fit
Equationy = a + b∗x
PlottingB2
Weightsunweighted
Intercept−0.24962 ± 8.99723 × 10⁻⁴−0.06512 ± 1.0321 × 10⁻⁴−0.01704 ± 1.12711 × 10⁻⁴
Slope0.00432 ± 7.1483 × 10−68.82355 × 10−4 ± 5.09002 × 10−71.63061 × 10−4 ± 2.98943 × 10⁻⁷
Residual sum of squares3.57422 × 10−41.03009 × 10−51.92627 × 10−5
Pearson’s r0.999870.999980.99975
R2 (COD)0.999740.999950.99951
Adjusted R20.999740.999950.9995
Table 5. Parameters of linear fits for B2 vs. position with different magnet materials.
N45 FitN40 FitN35 FitN30 FitFE5B Fit
Equationy = a + b∗x
PlottingB2
Weightsunweighted
Intercept−0.23836 ± 0.00136−0.21634 ± 0.00123−0.19213 ± 0.00109−0.16053 ± 9.14378 × 10⁻⁴−0.02155 ± 1.22406 × 10⁻⁴
Slope0.00423 ± 1.11061 × 10−50.00384 ± 1.00833 × 10−50.00341 ± 8.95867 × 10−60.00285 ± 7.48659 × 10−63.82612 × 10−4 ± 1.00221 × 10⁻⁶
Residual sum of squares0.001890.001550.001238.56793 × 10−41.53542 × 10⁻⁵
Pearson’s r0.99960.99960.99960.99960.9996
R2 (COD)0.99920.99920.99920.99920.9992
Adjusted R20.99920.999190.999190.999190.9992
Table 6. Parameters of linear fits for B2 vs. position with varying bilateral magnet lengths.
30 Fit40 Fit50 Fit60 Fit70 Fit80 Fit
Equationy = a + b∗x
PlottingB2
Weightsunweighted
Intercept−0.09607 ± 0.00181−0.21284 ± 7.82598 × 10⁻⁴−0.24922 ± 9.61624 × 10⁻⁴−0.28833 ± 0.00121−0.33157 ± 0.0015−0.17155 ± 0.00433
Slope0.00198 ± 1.47673 × 10−50.00367 ± 6.37621 × 10−60.00432 ± 7.82697 × 10−60.00501 ± 9.8217 × 10−60.00579 ± 1.22176 × 10−50.00378 ± 3.52426 × 10⁻⁵
Residual sum of squares0.00142.63977 × 10−43.92974 × 10−46.18901 × 10−49.57681 × 10−40.00797
Pearson’s r0.997430.999860.999850.999820.999790.99598
R2 (COD)0.994870.999720.999690.999640.999590.99199
Adjusted R20.994810.999710.999690.999640.999580.9919
Table 7. Parameters of linear fits for B2 vs. position with varying pole spacing.
40 Fit50 Fit60 Fit70 Fit
Equationy = a + b∗x
PlottingB2
Weightsunweighted
Intercept−0.34723 ± 0.00419−0.25083 ± 8.8841 × 10⁻⁴−0.18522 ± 0.00134−0.13925 ± 0.00226
Slope0.00539 ± 3.346 × 10−50.00433 ± 6.98846 × 10−60.00356 ± 1.06437 × 10−50.003 ± 1.77641 × 10⁻⁵
Residual sum of squares0.007343.00954 × 10−47.20706 × 10−40.00213
Pearson’s r0.998210.999880.999580.9983
R2 (COD)0.996430.999760.999150.9966
Adjusted R20.996390.999760.999140.99656
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content.