Article

Miniature Mobile Robot Using Only One Tilted Vibration Motor
1
Shenzhen Key Laboratory of Biomimetic Robotics and Intelligent Systems, Department of Mechanical and Energy Engineering, Southern University of Science and Technology, Shenzhen 518055, China
2
Guangdong Provincial Key Laboratory of Human-Augmentation and Rehabilitation Robotics in Universities, Southern University of Science and Technology, Shenzhen 518055, China
3
Southern Marine Science and Engineering Guangdong Laboratory, Guangzhou 511458, China
*
Author to whom correspondence should be addressed.
Micromachines 2022, 13(8), 1184; https://doi.org/10.3390/mi13081184
Submission received: 25 June 2022 / Revised: 22 July 2022 / Accepted: 23 July 2022 / Published: 27 July 2022

Abstract

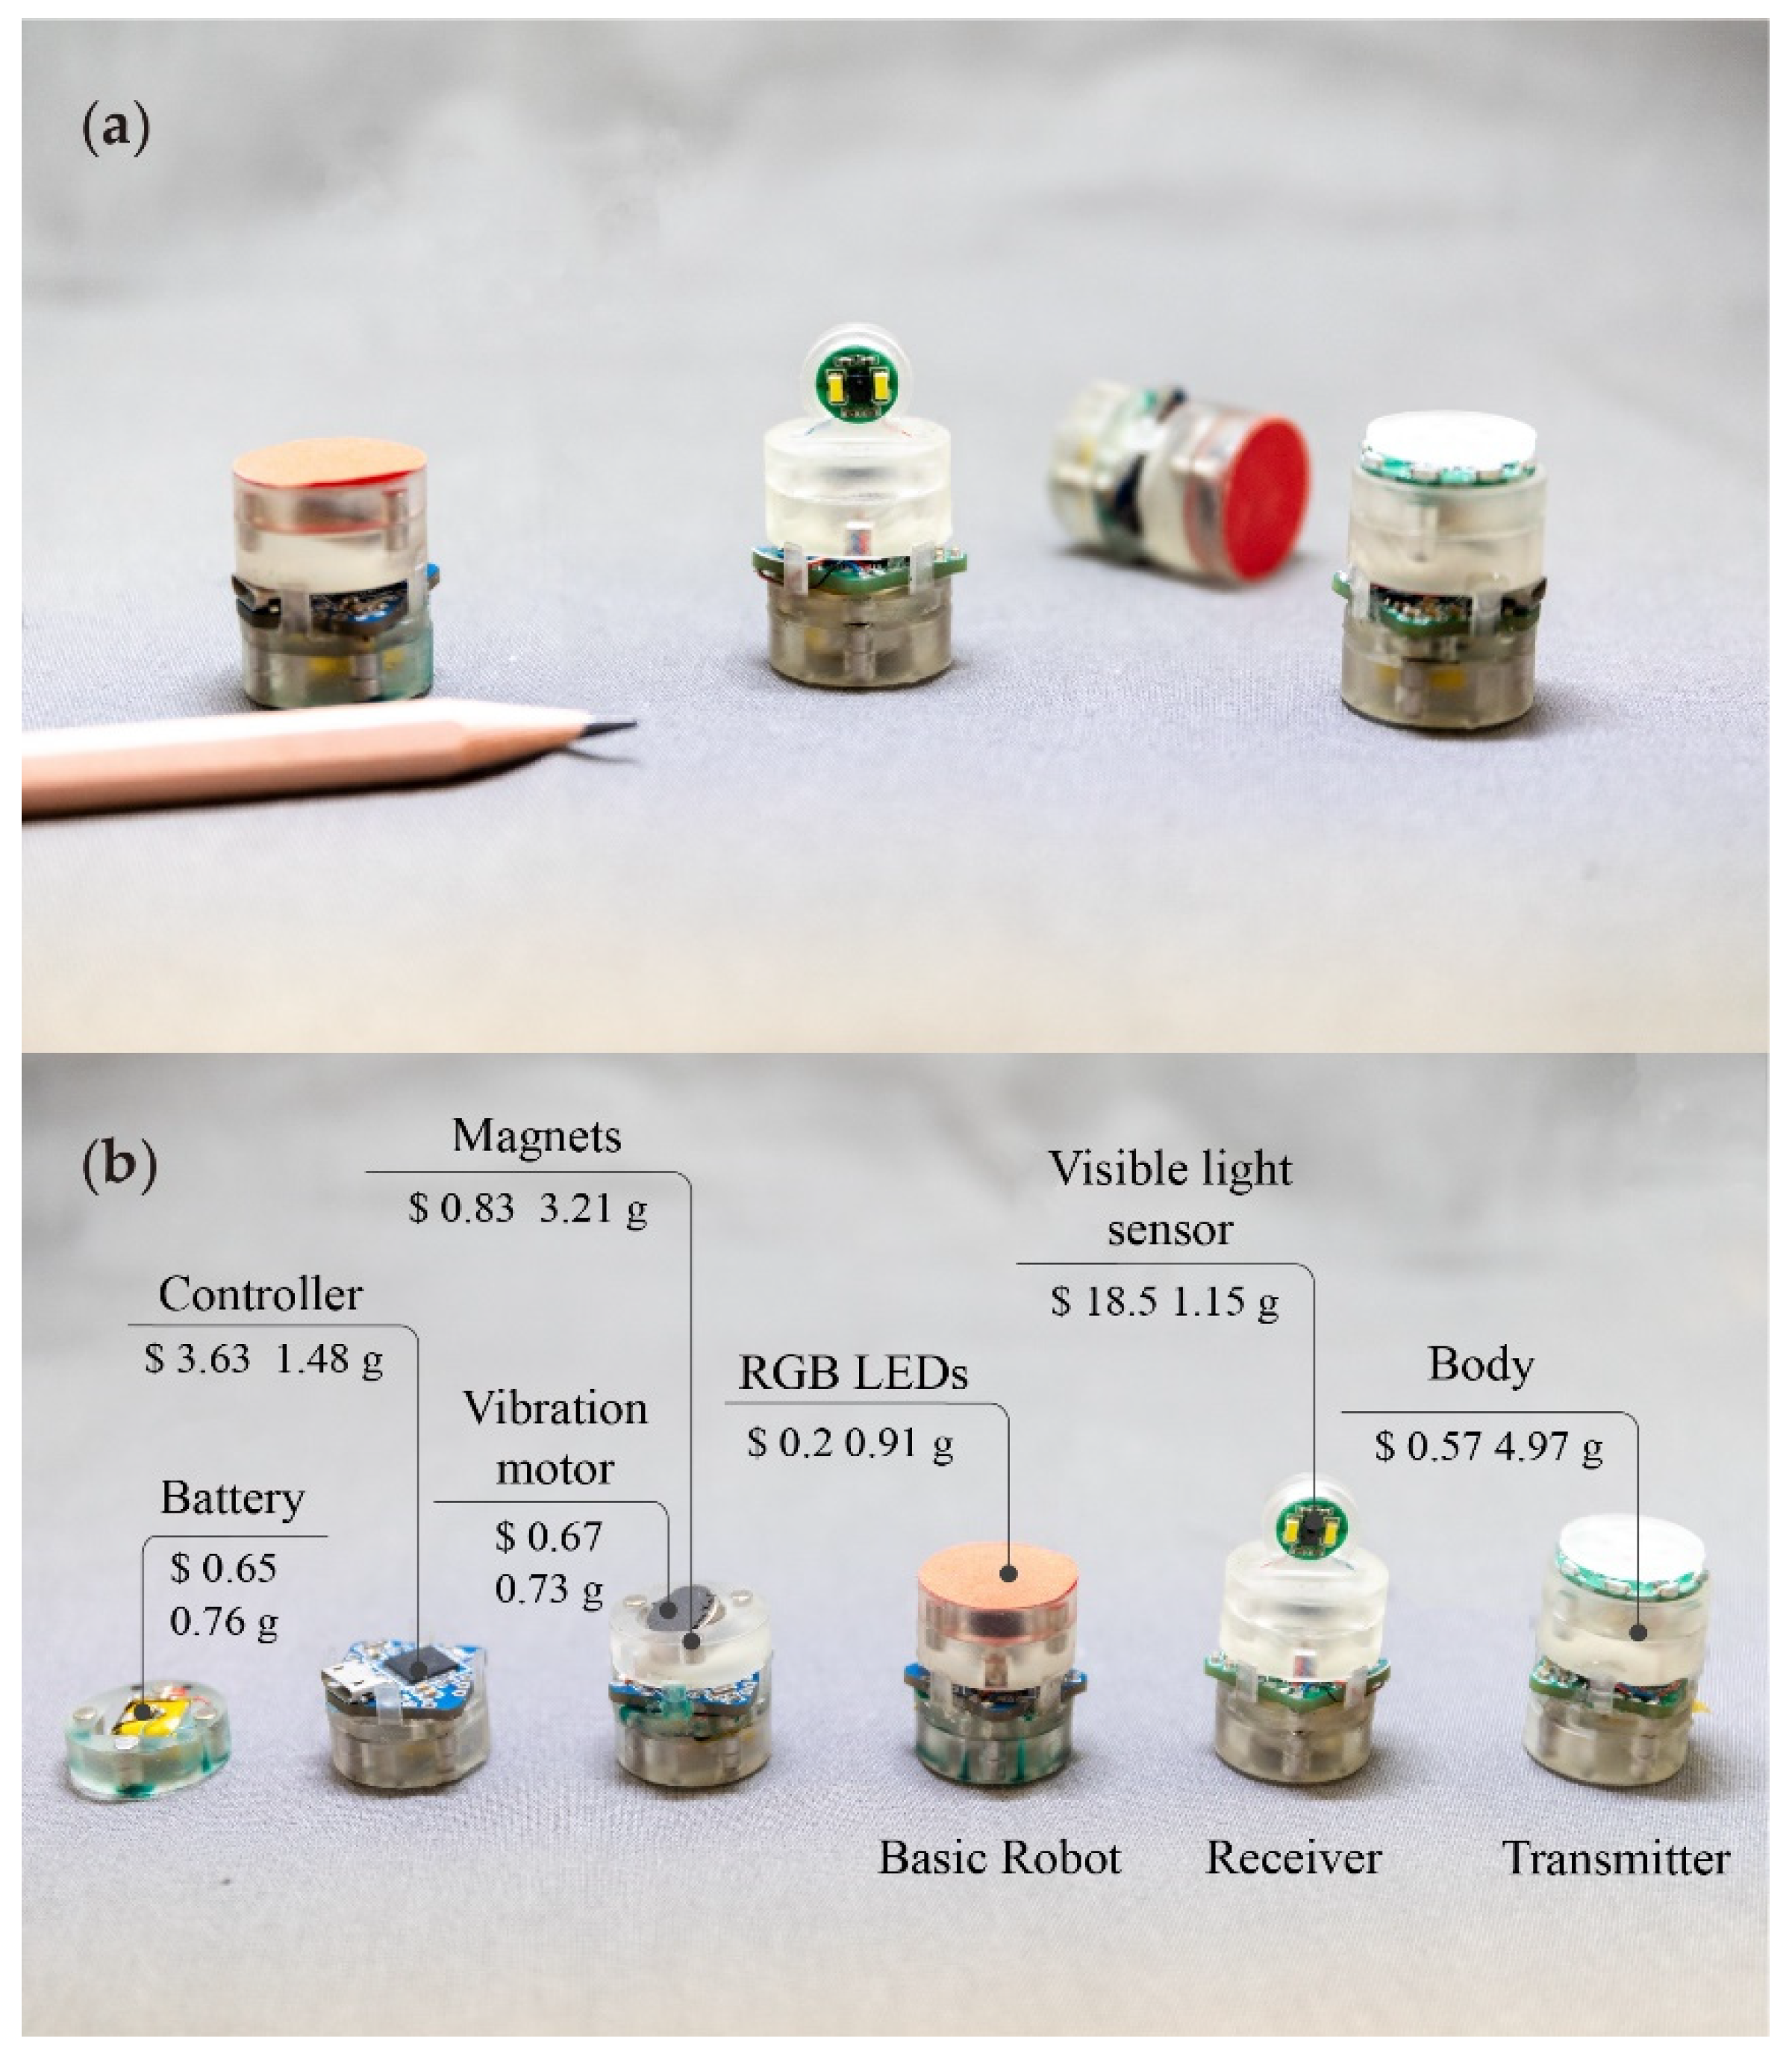
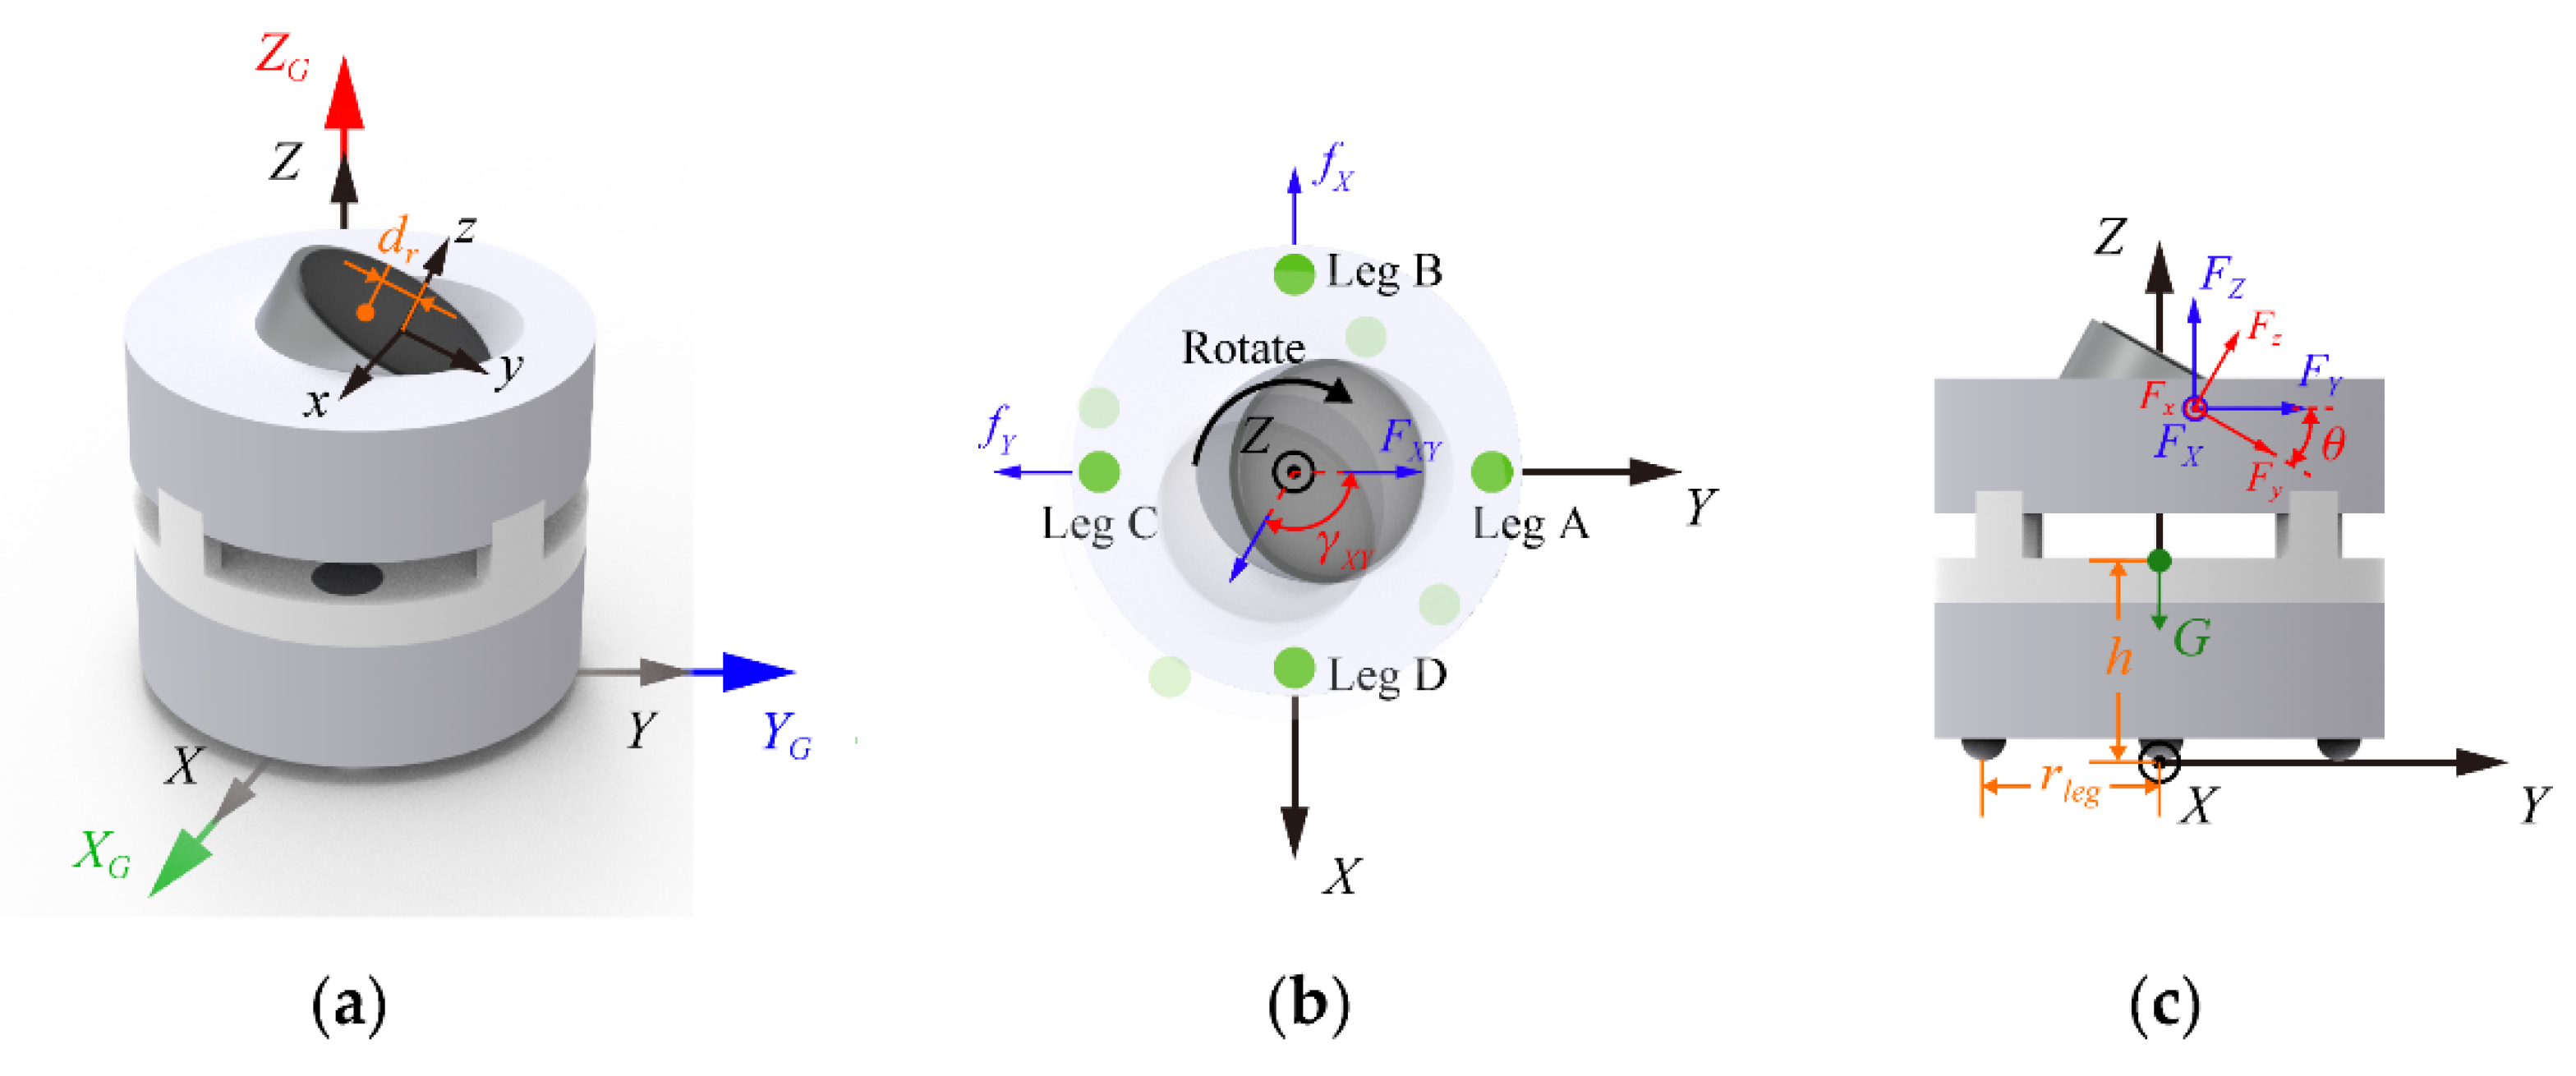
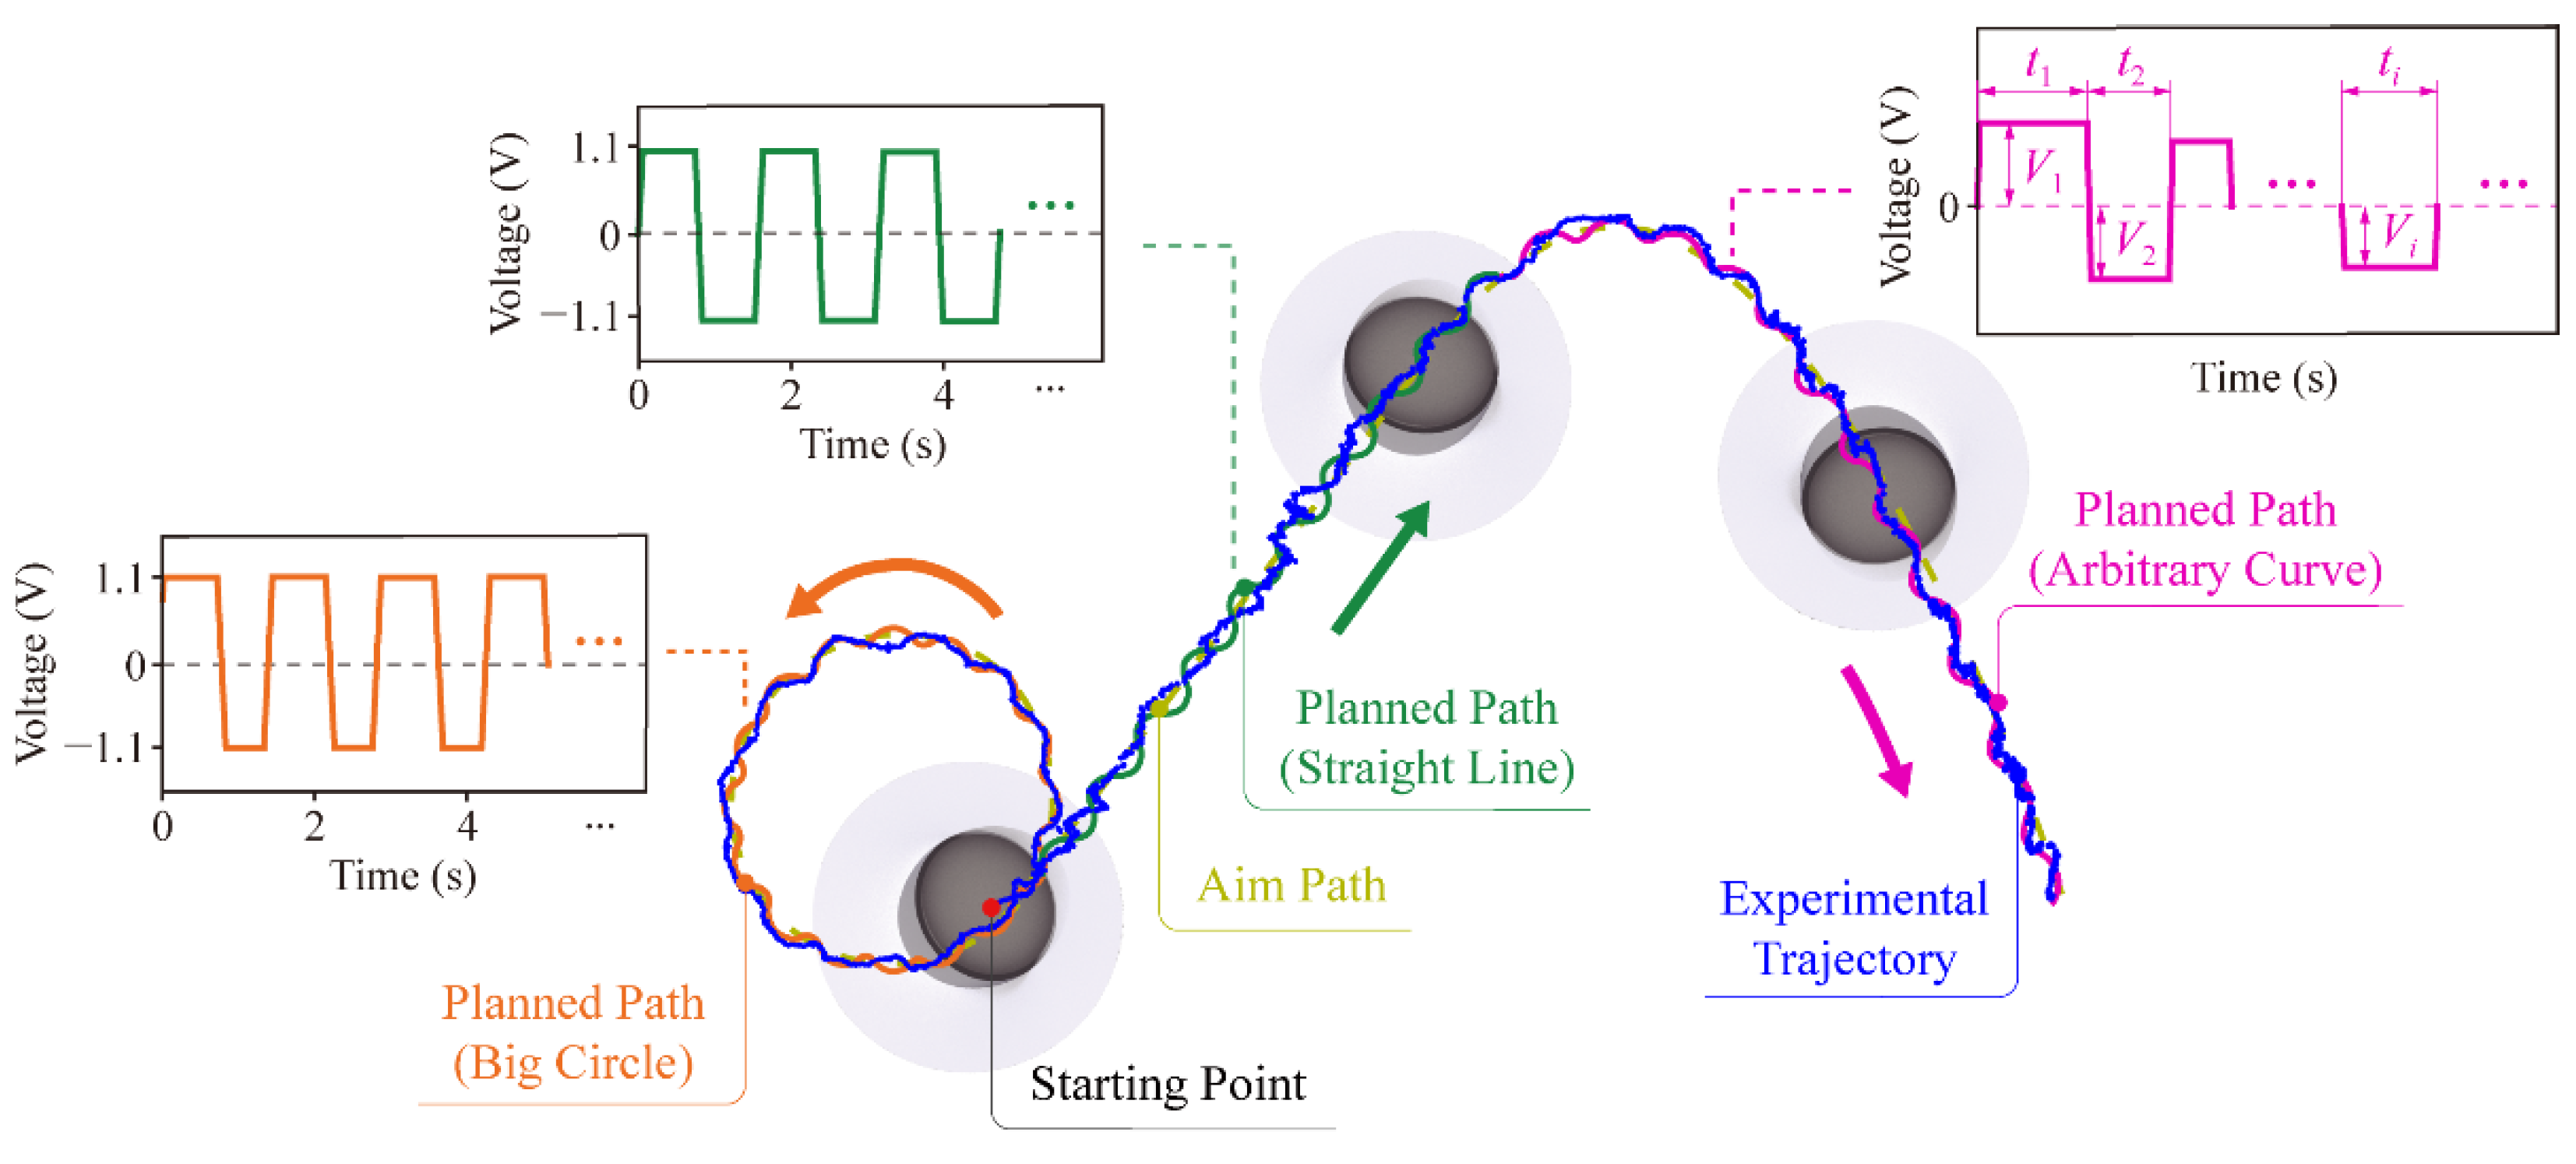
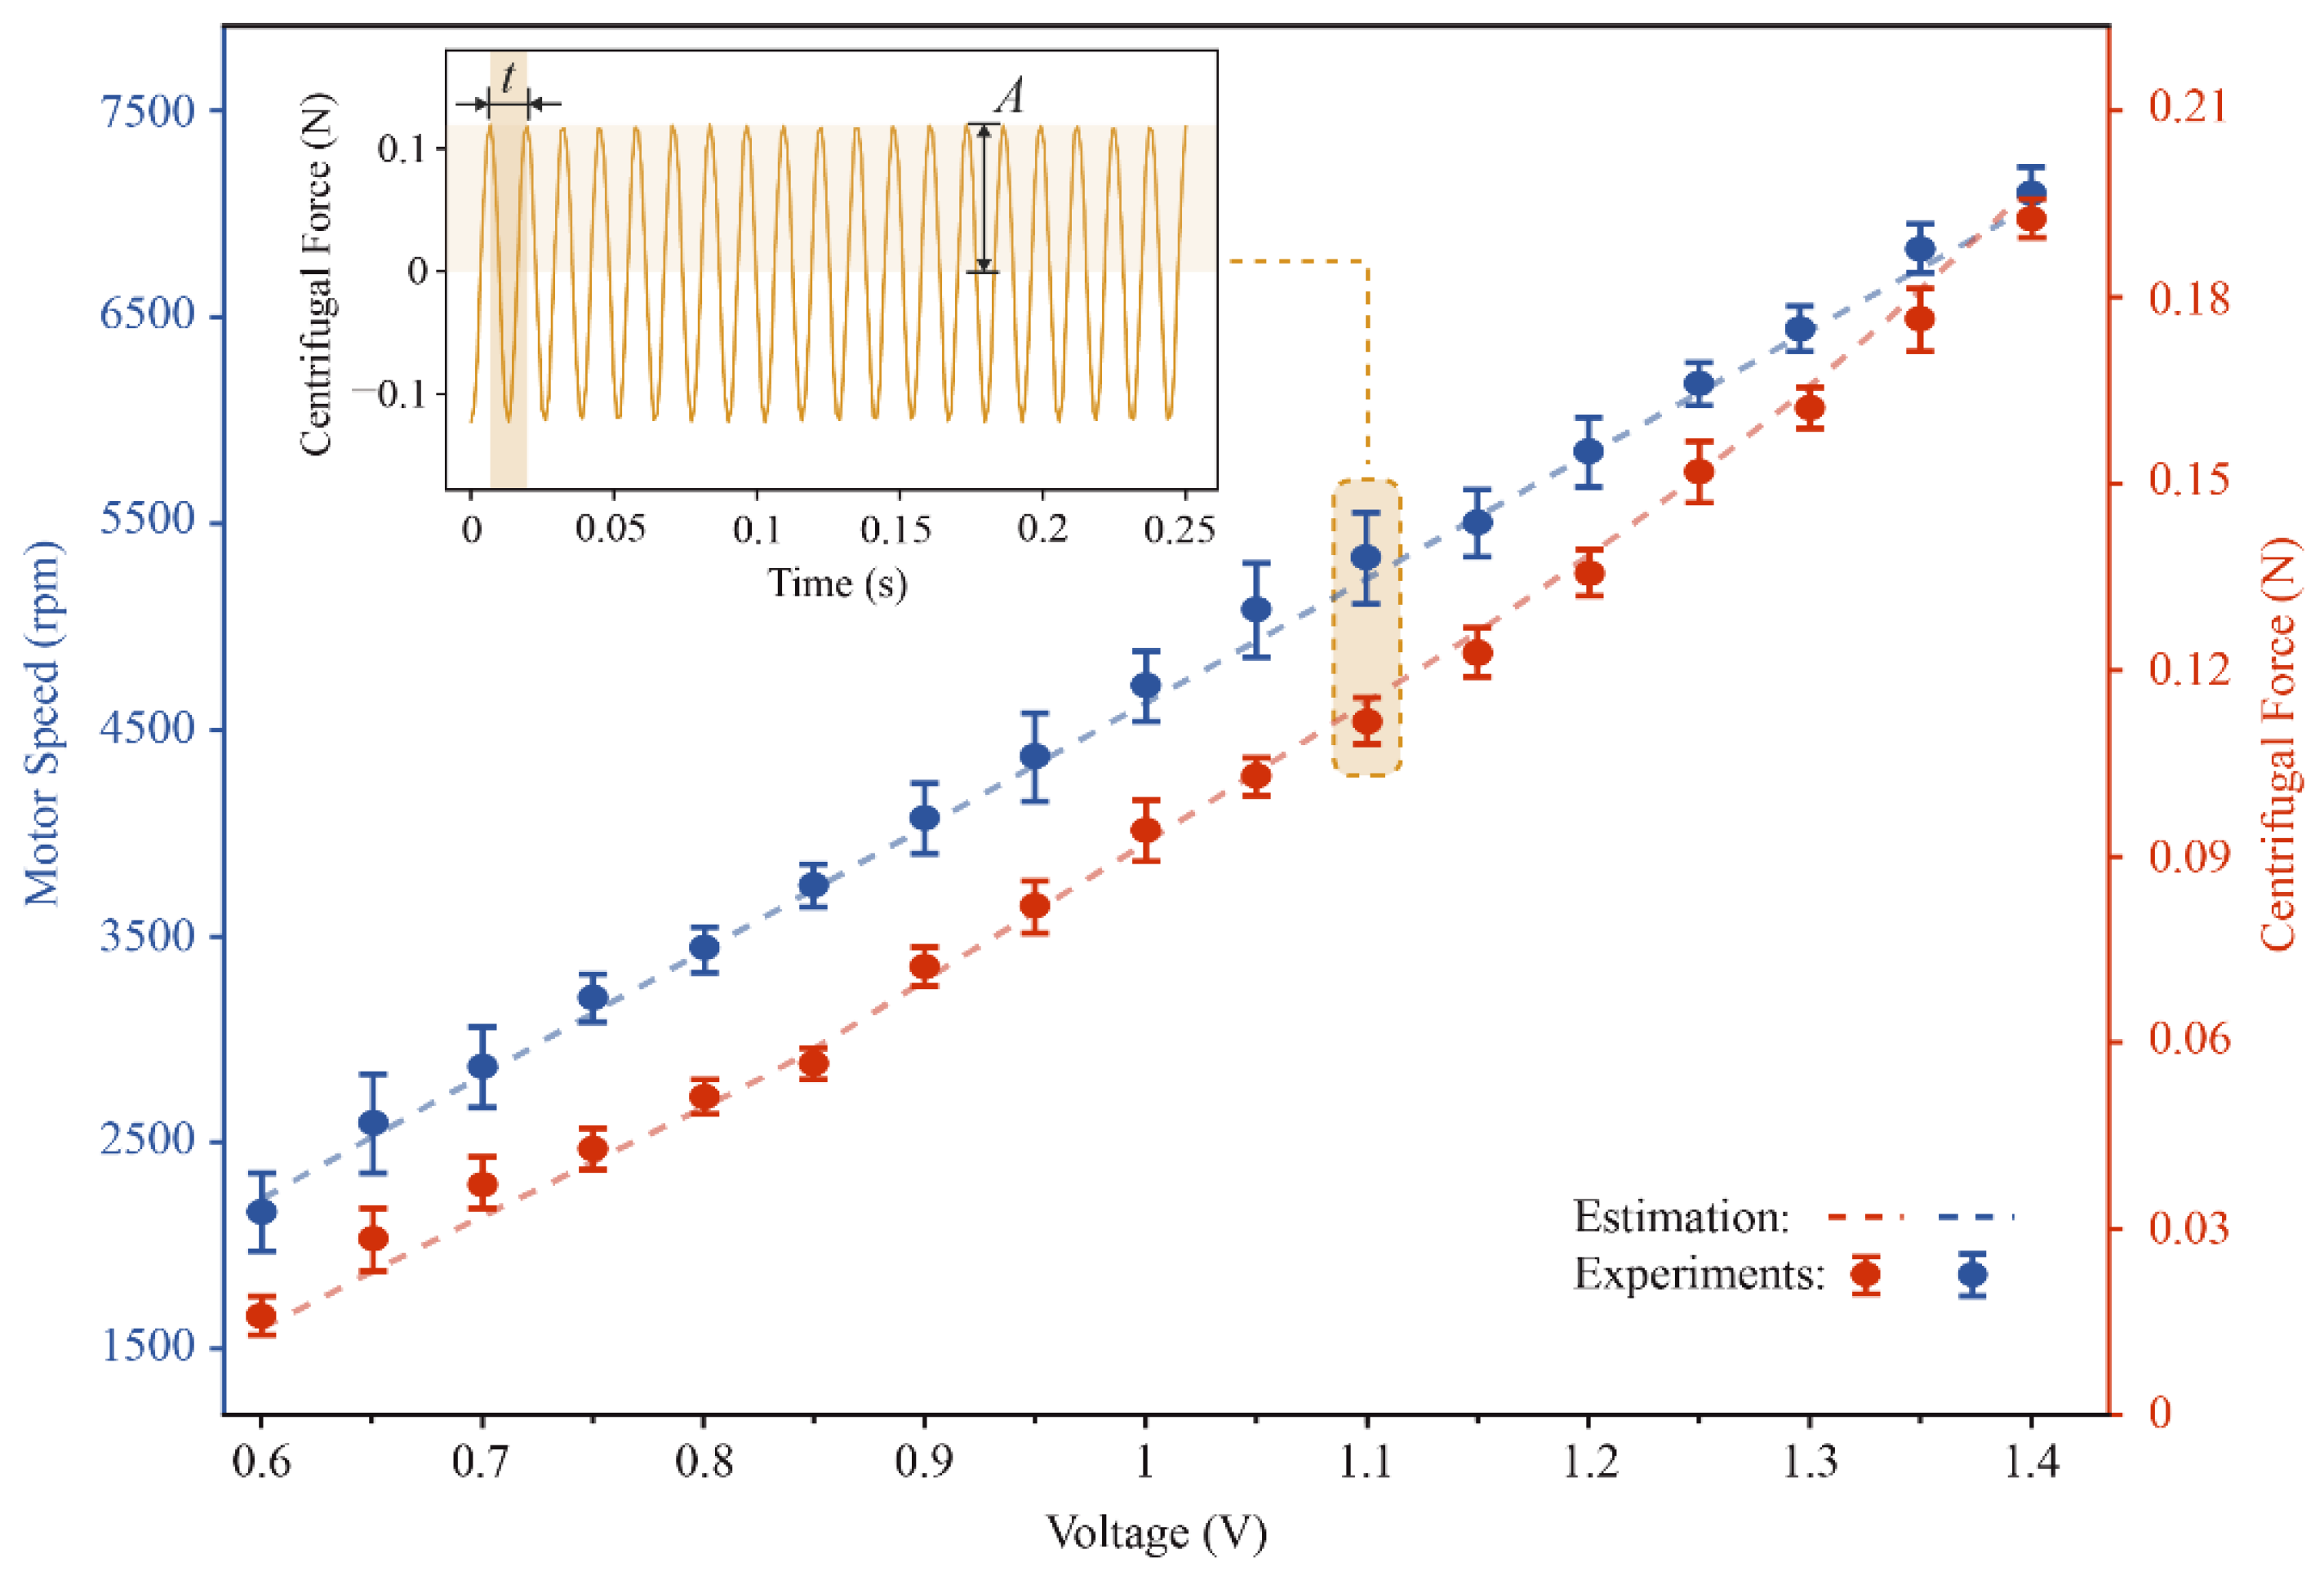
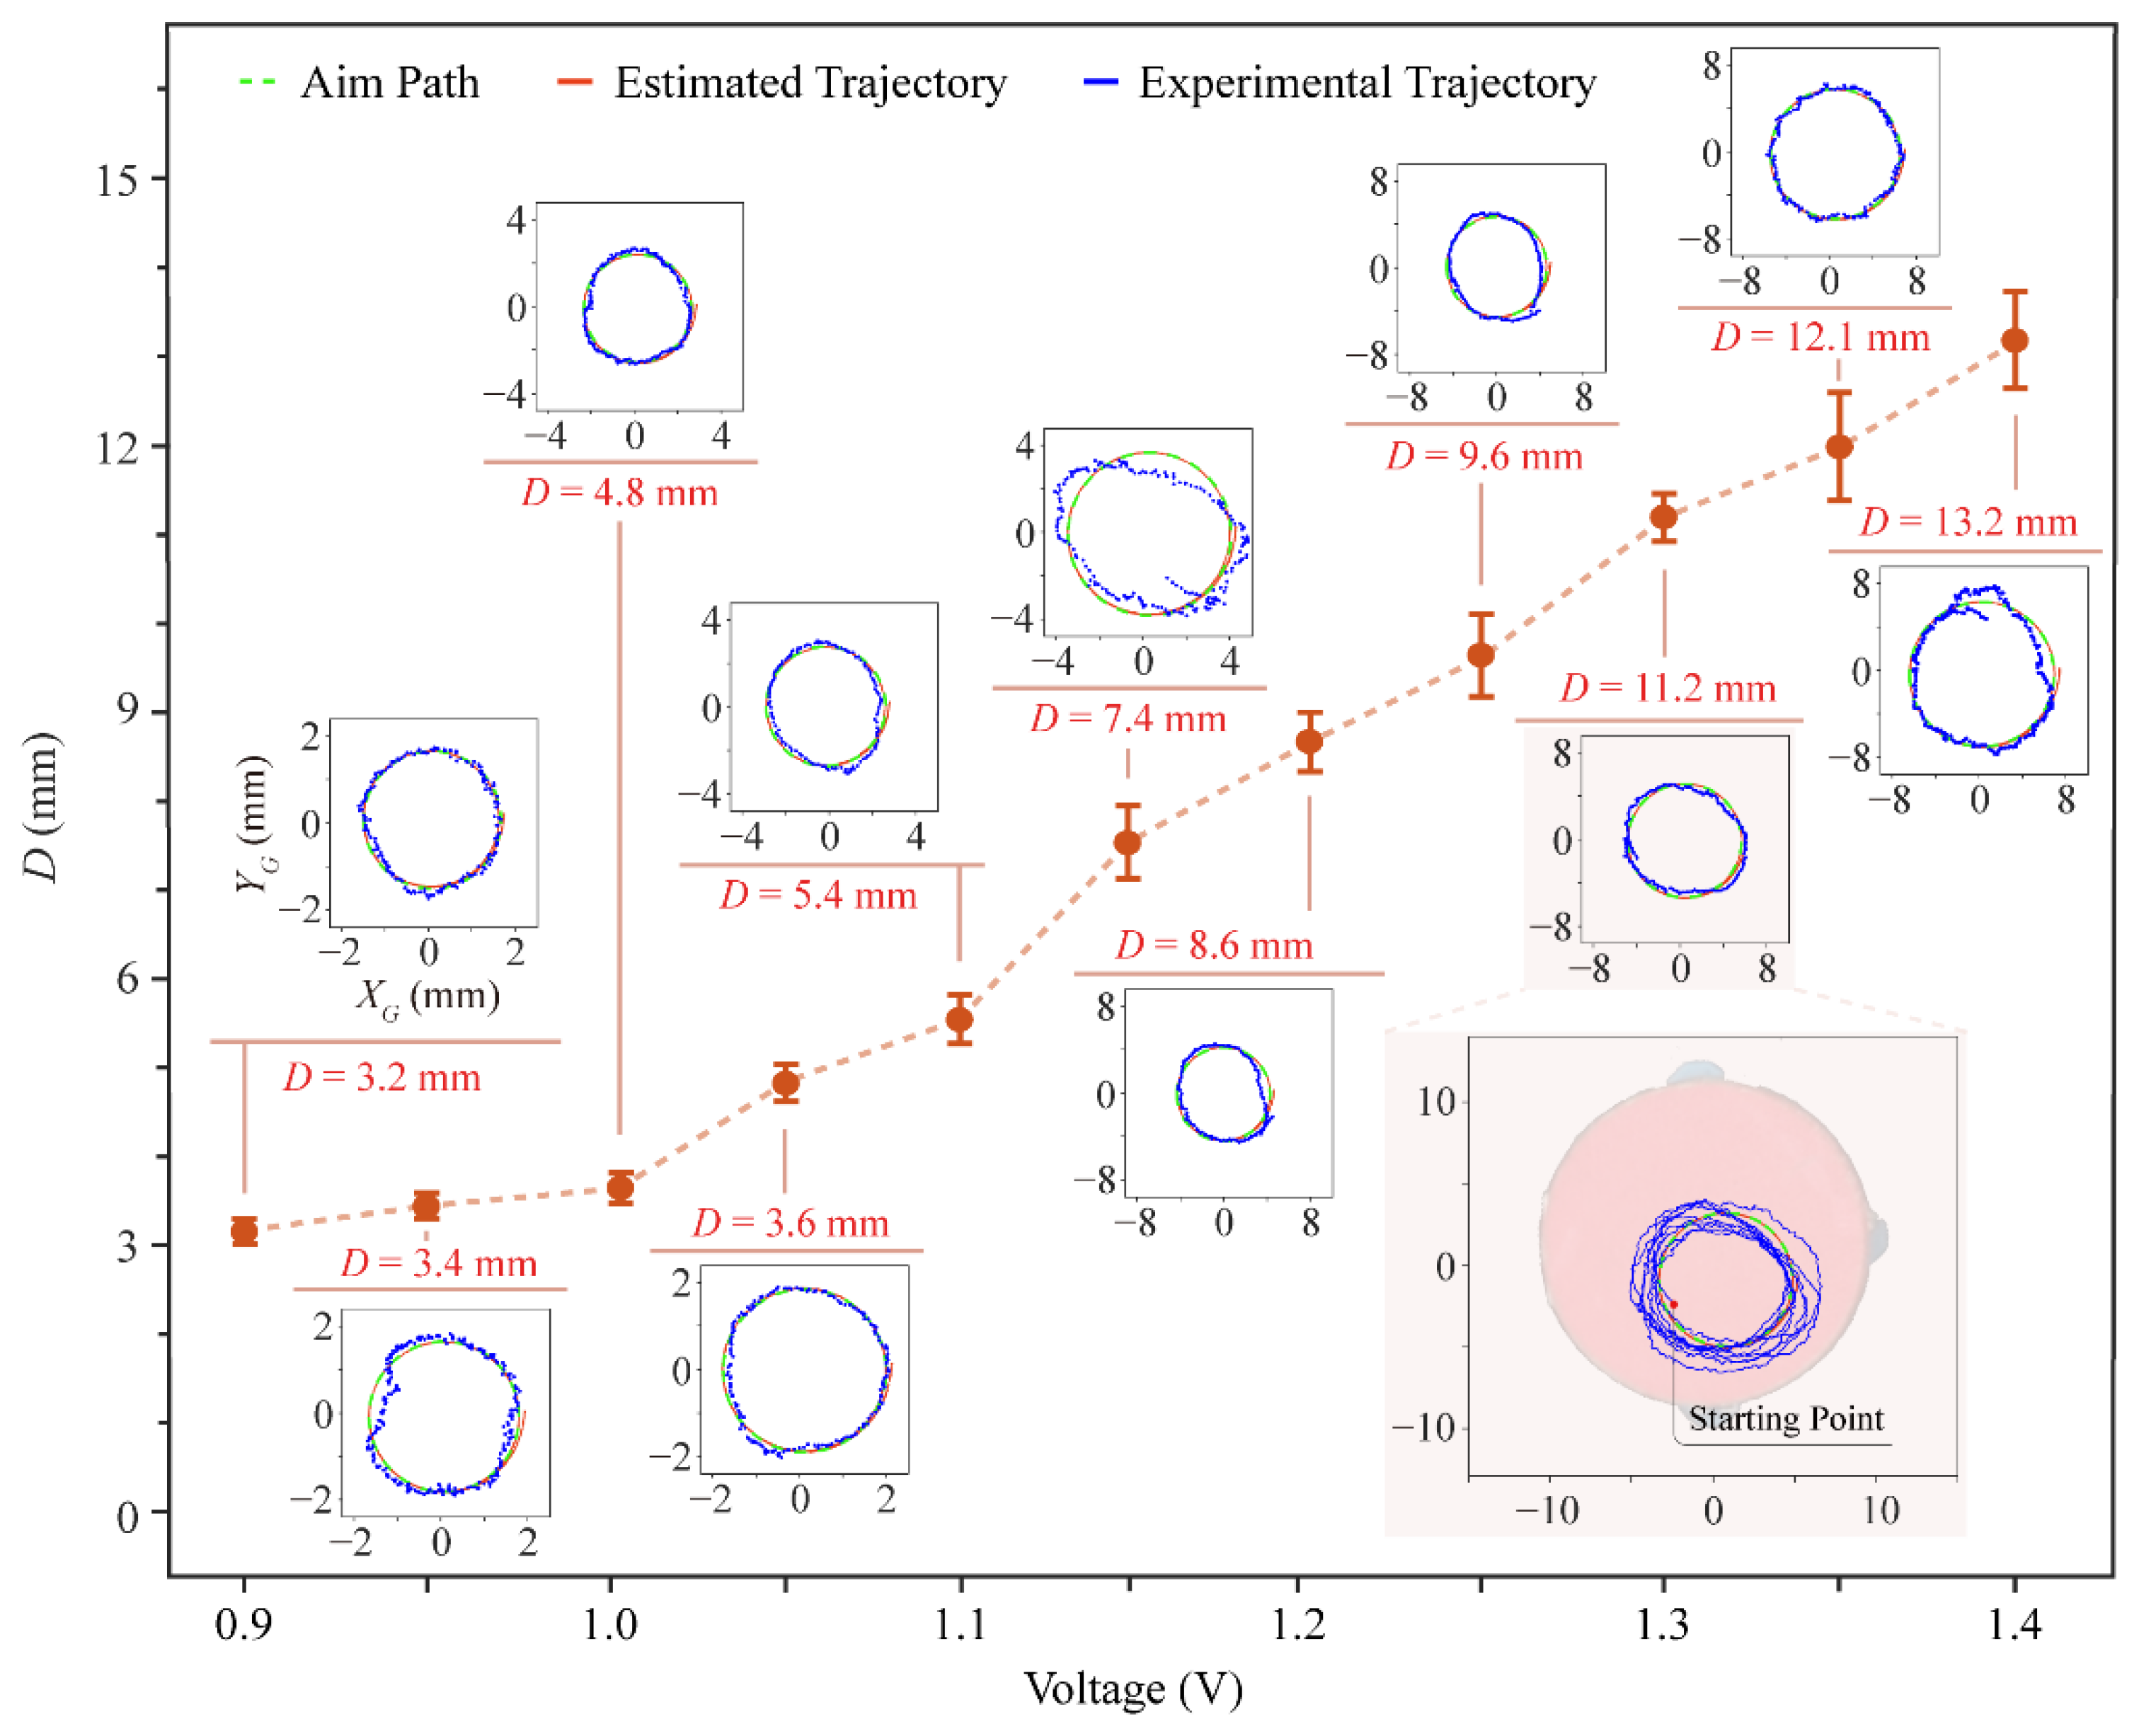
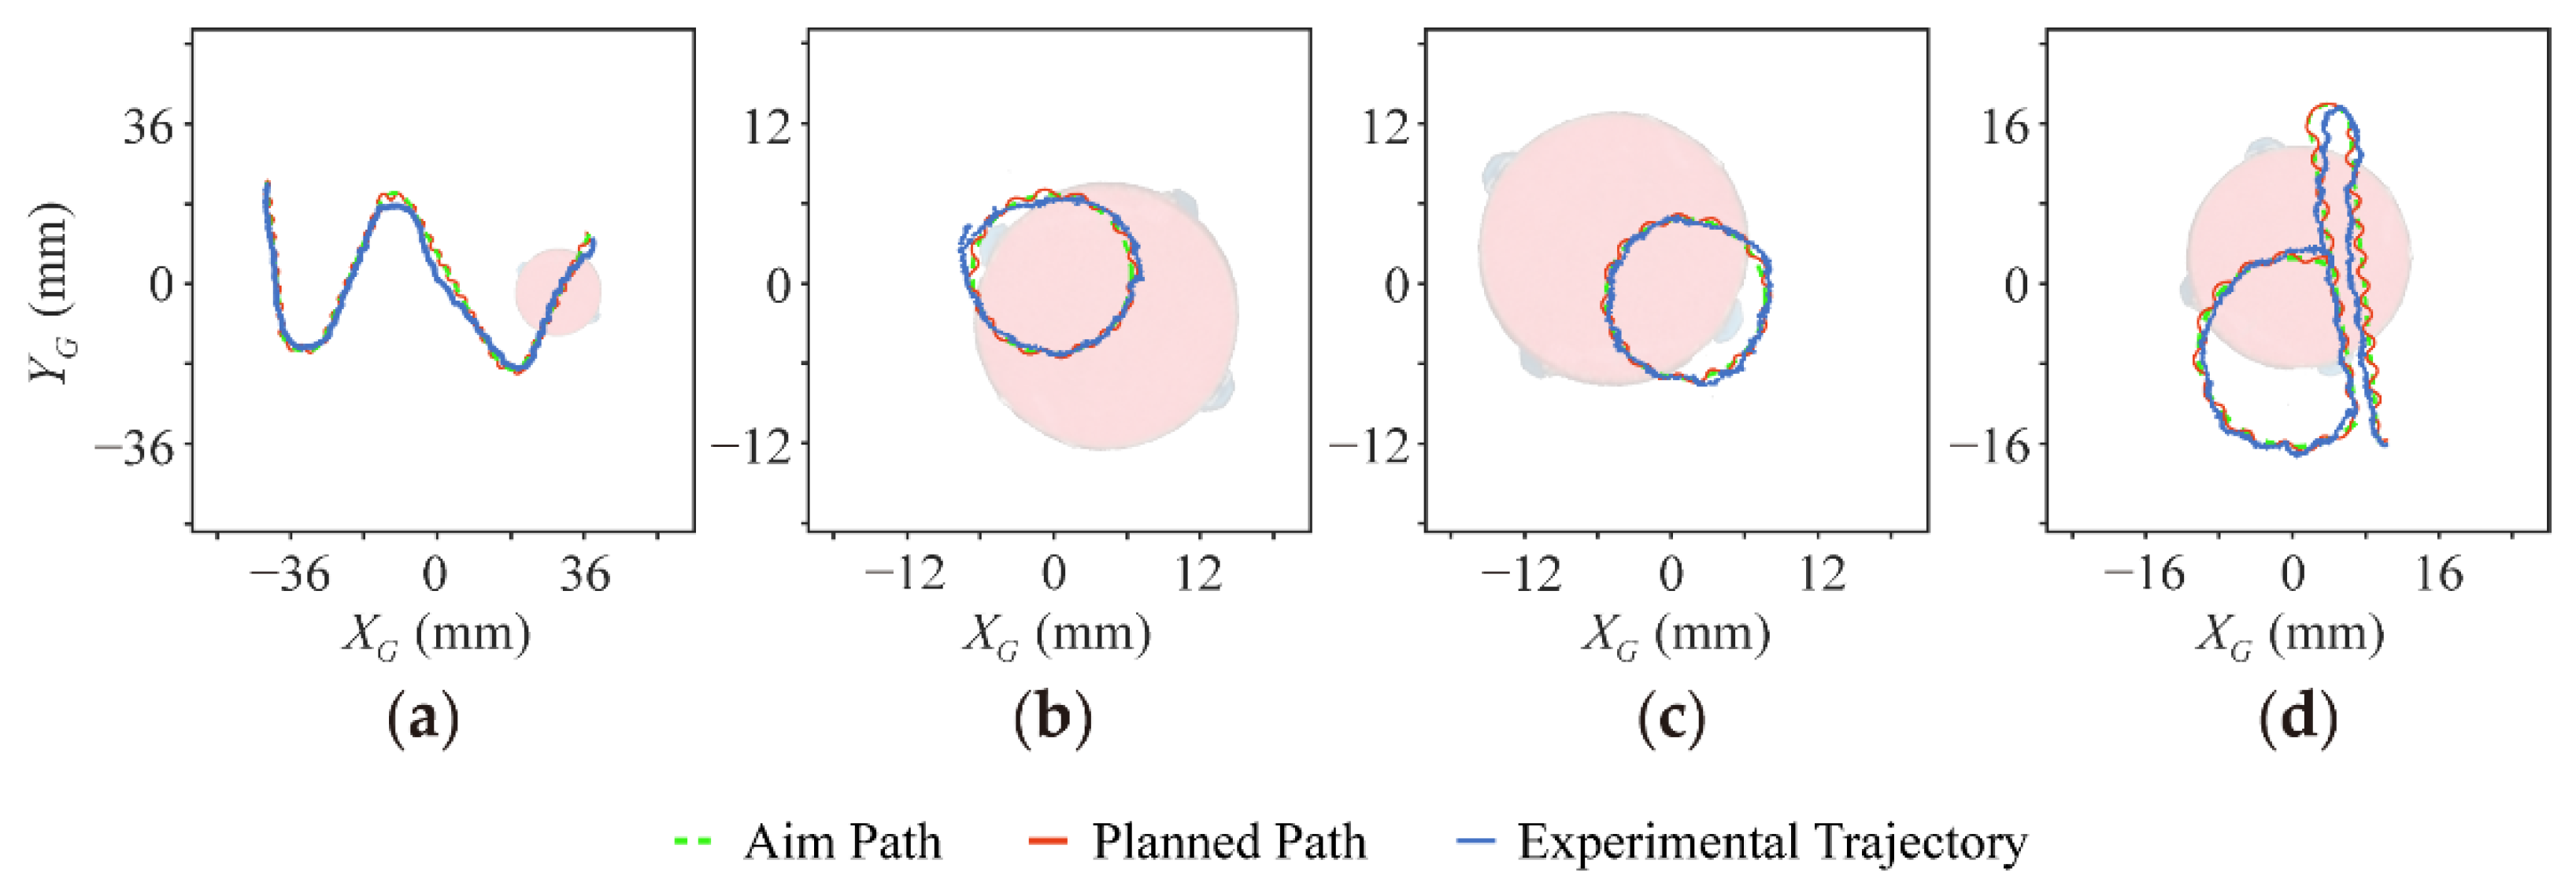
In miniature mobile robots, reducing the number of actuators can effectively reduce the size and weight of the robot. However, it is challenging to design a robot with as few actuators as possible without losing good motion performance. This work presented a simple-structured low-cost miniature mobile robot. It is driven by only a single tilted motor and yet is fully capable of being controlled to move forward and turn left or right on the ground. Based on the stick–slip mechanism, the robot’s motion is achieved by interplaying between the centrifugal force generated by the vibration motor tilted on the robot and the friction force of the robot. The robot’s speed can be controlled by regulating the magnitude and the period of the applied voltage. Finally, the robot can translate and rotate on the ground and follow various arbitrary paths. The prototype weighs only 11.15 g, costs $6.35, and is 20 mm in diameter and 25 mm in height. The proposed system is experimentally verified and demonstrates the controllability of the robot by the movement along a straight line, a circle, and more arbitrary paths.
Keywords: miniature robots; underactuated robots; swarms; mechanism design miniature robots; underactuated robots; swarms; mechanism design