A Coarse-to-Fine Optical-SAR Image Registration Algorithm for UAV-Based Multi-Sensor Systems Using Geographic Information Constraints and Cross-Modal Feature Consistency Mapping

 ,
Highlights
- A coarse-to-fine registration framework integrating geographic information constraints with cross-modal feature consistency mapping is proposed, achieving automatic elimination of scale differences and rotation deviations between optical and SAR images through imaging geometry-based coordinate transformation.
- On the integrated airborne optical/SAR dataset, the method achieves 2.00 (CPU)/1.97 (GPU) pixels in average RMSE, outperforming traditional and state-of-the-art deep learning methods while reducing computation time by 37.0%; its geographic-constrained coarse registration improves SuperGlue/LoFTR CMR by 167%/109%, and the hybrid GLS + LightGlue refinement yields the optimal 1.95-pixel RMSE with GPU acceleration.
- The geographic information constraint approach circumvents radiometric differences that challenge both traditional intensity-based methods and data-driven deep learning approaches, providing a practical registration framework for UAV-based multi-sensor fusion systems in GNSS-aided scenarios.
- The method demonstrates robust performance under challenging conditions (dense smoke, fire, illumination variations) and provides the best accuracy–efficiency trade-off for resource-constrained UAV platforms, enabling real-time applications in environmental monitoring, disaster assessment, target detection, and visual navigation tasks.
- The demonstrated complementary benefits between geometric constraints and learned features suggest promising directions for future hybrid approaches combining physics-based geometric priors with data-driven feature representations for cross-modal image matching.
Abstract
1. Introduction
- (1)
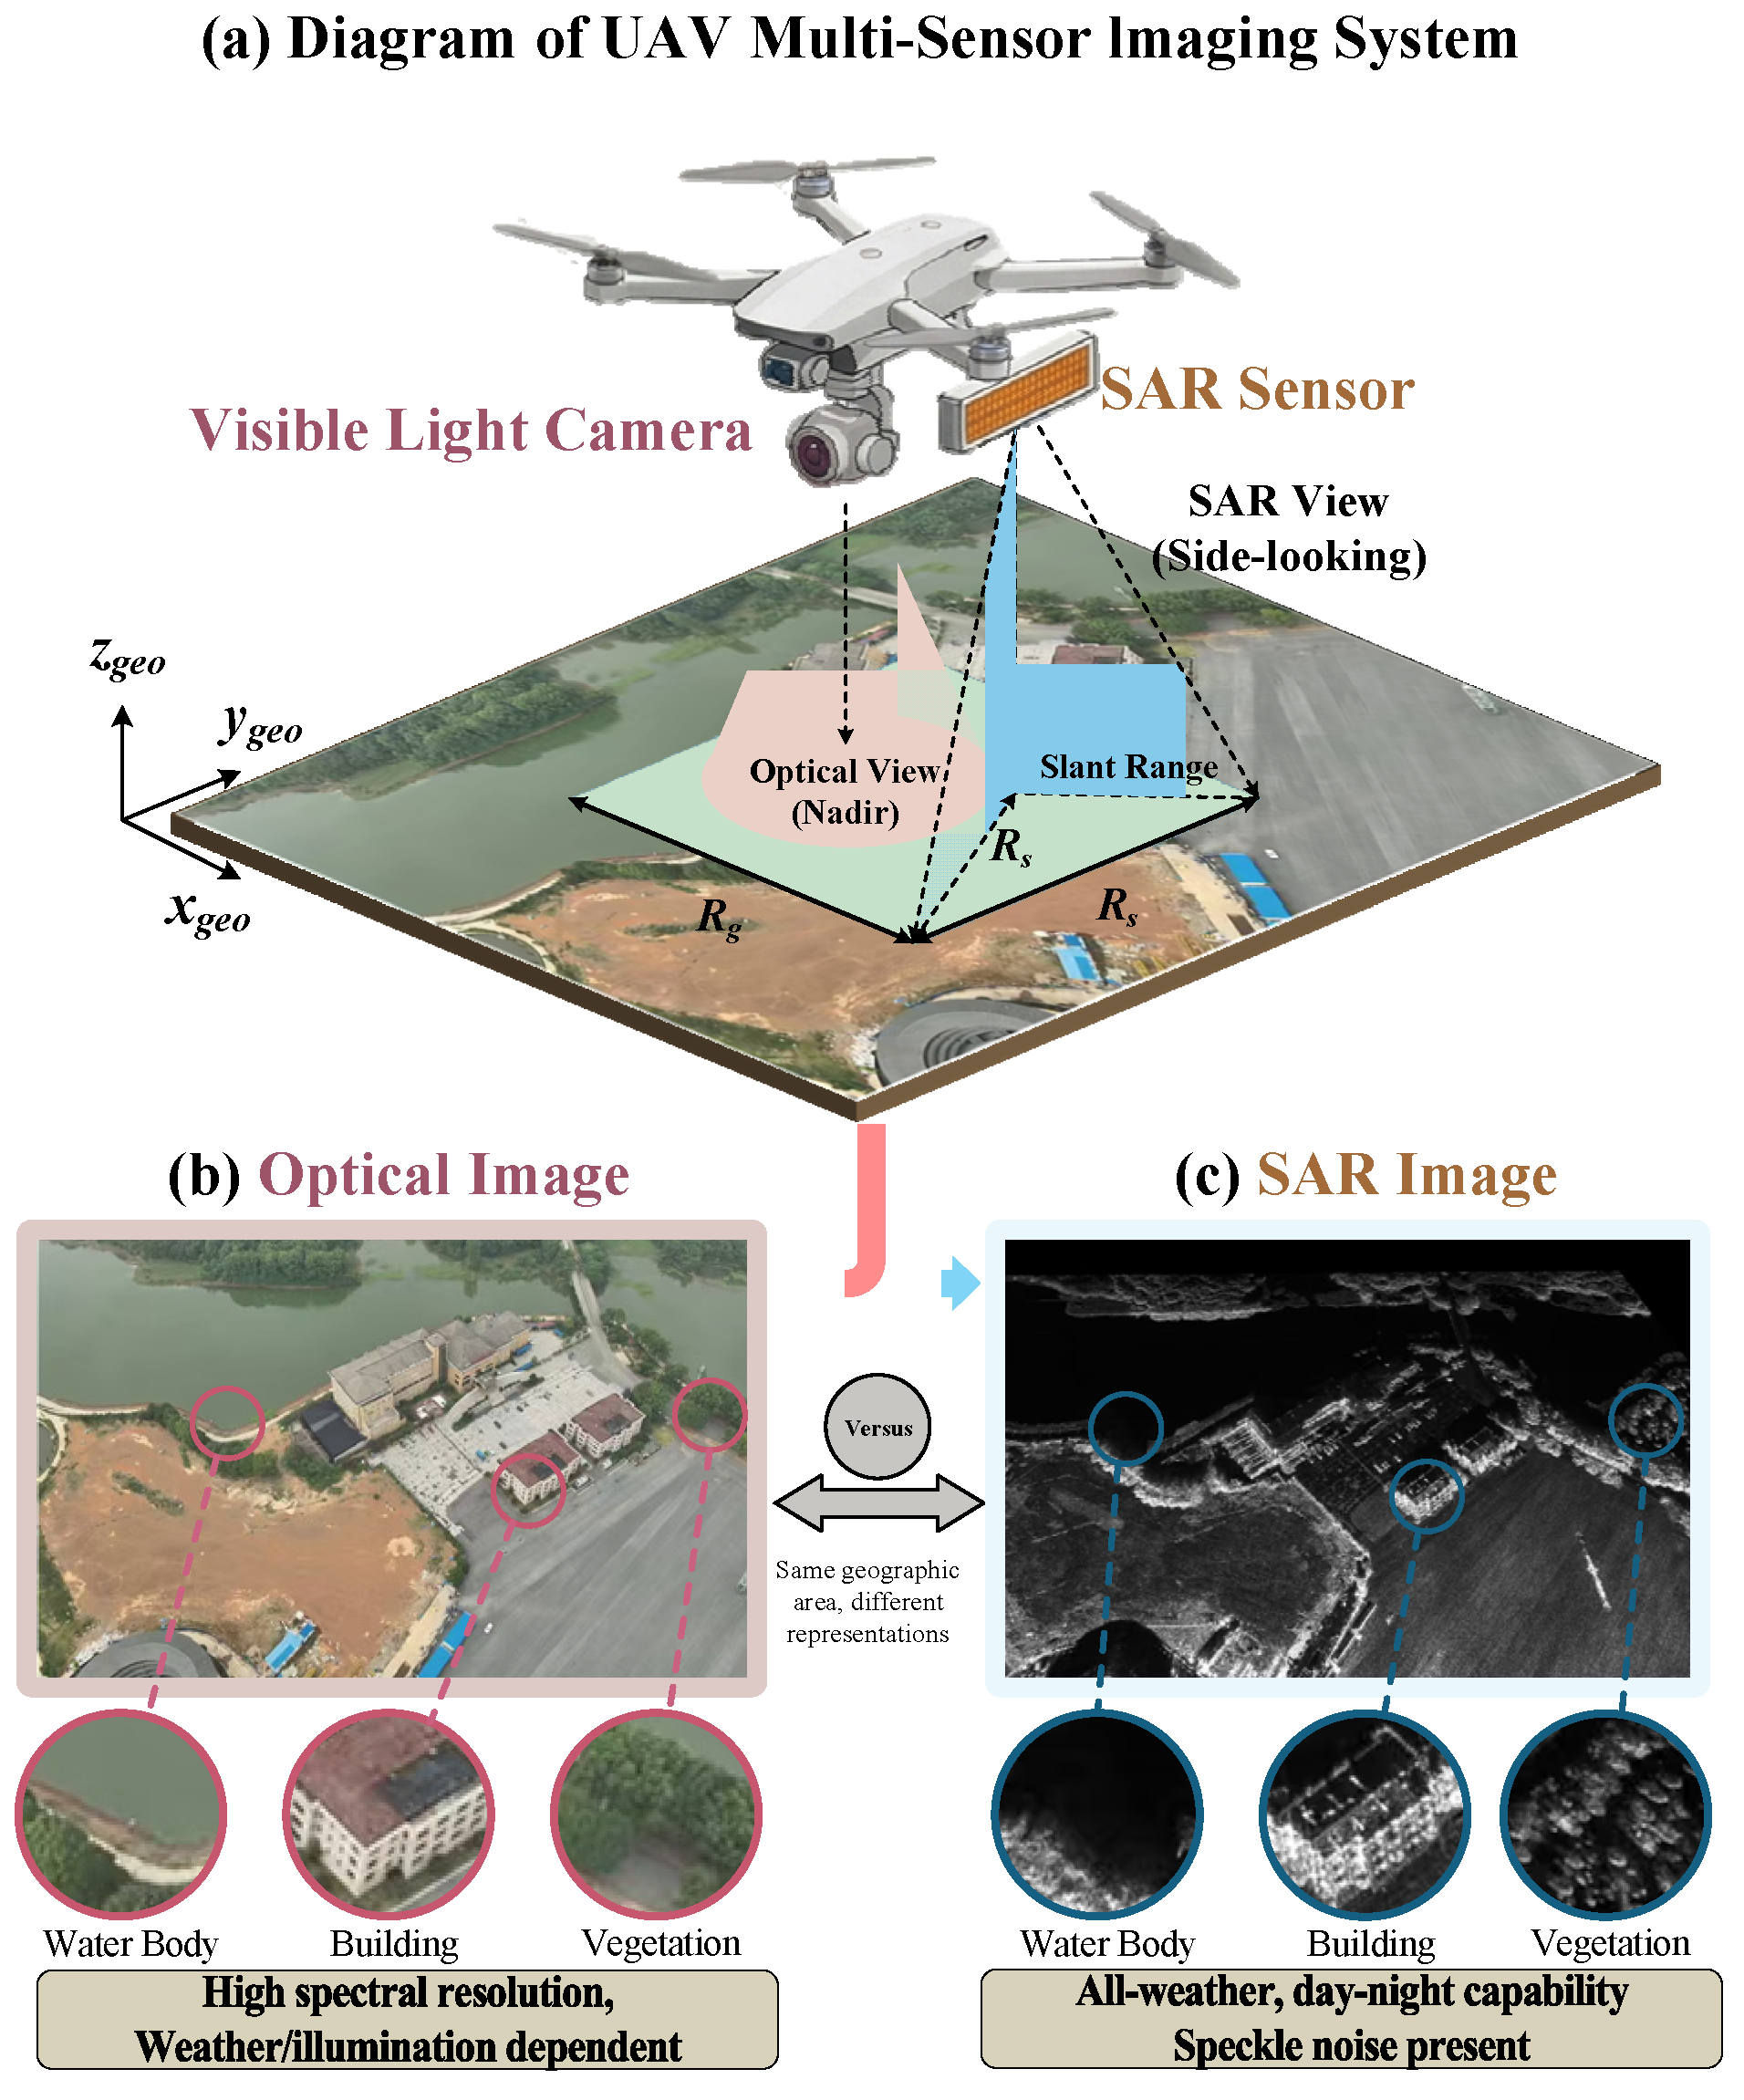
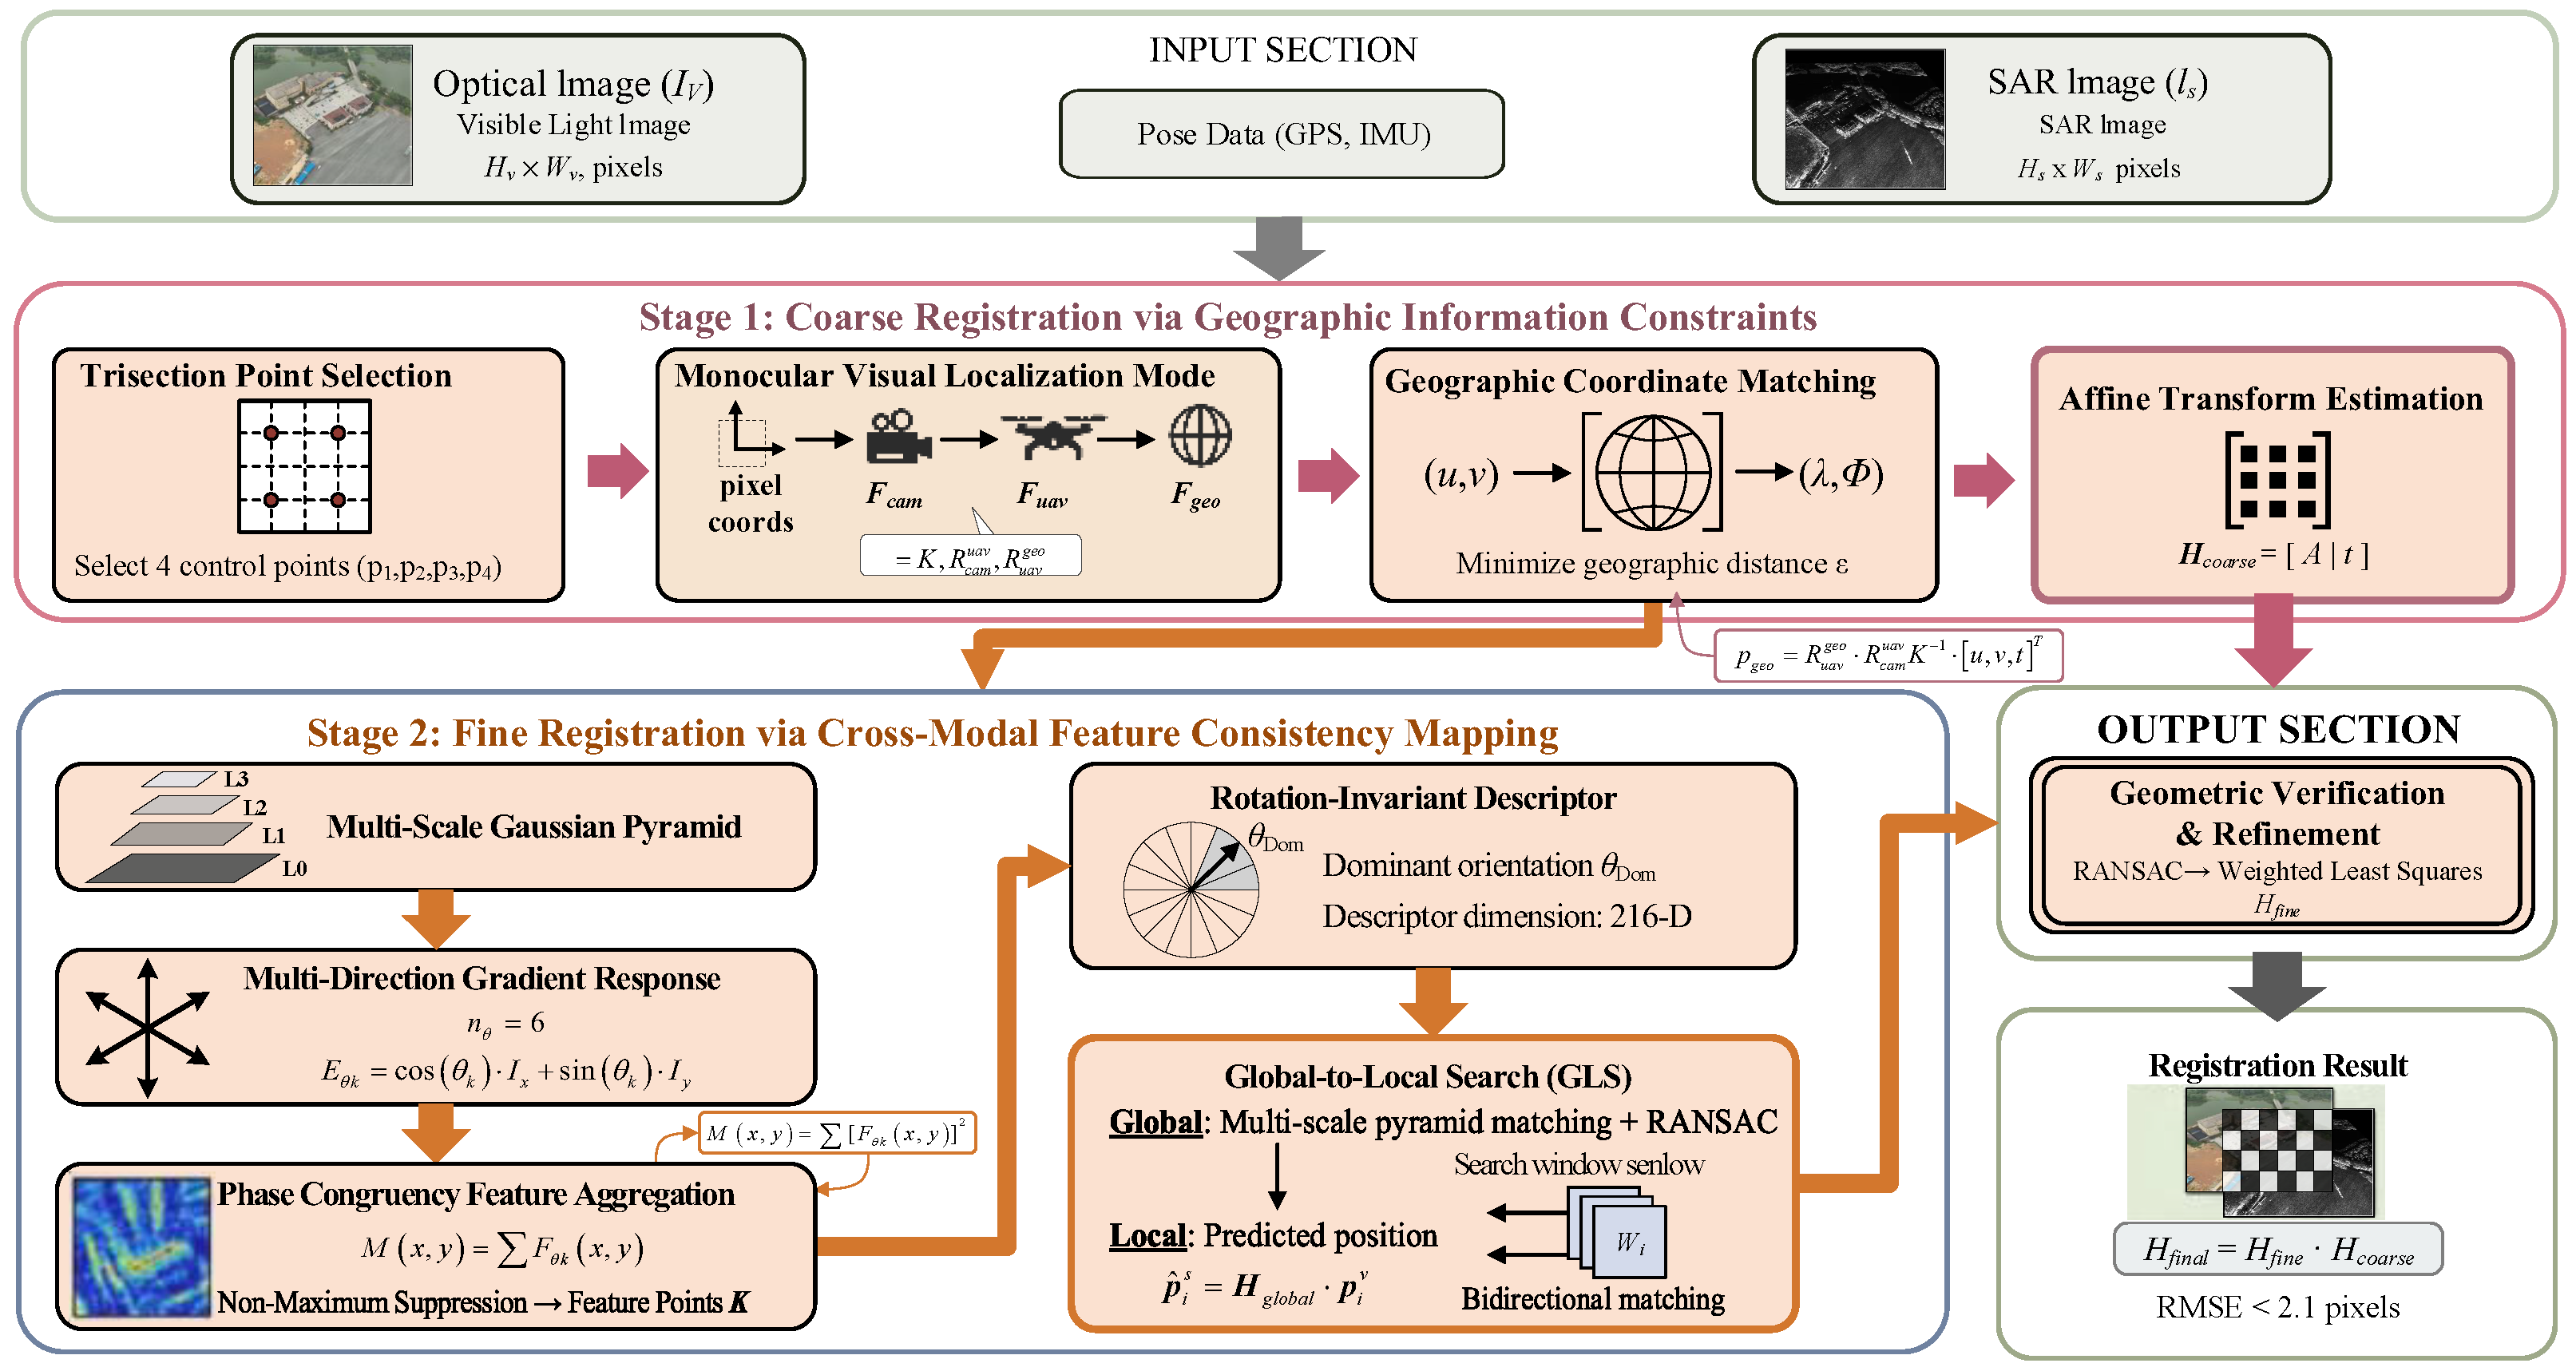
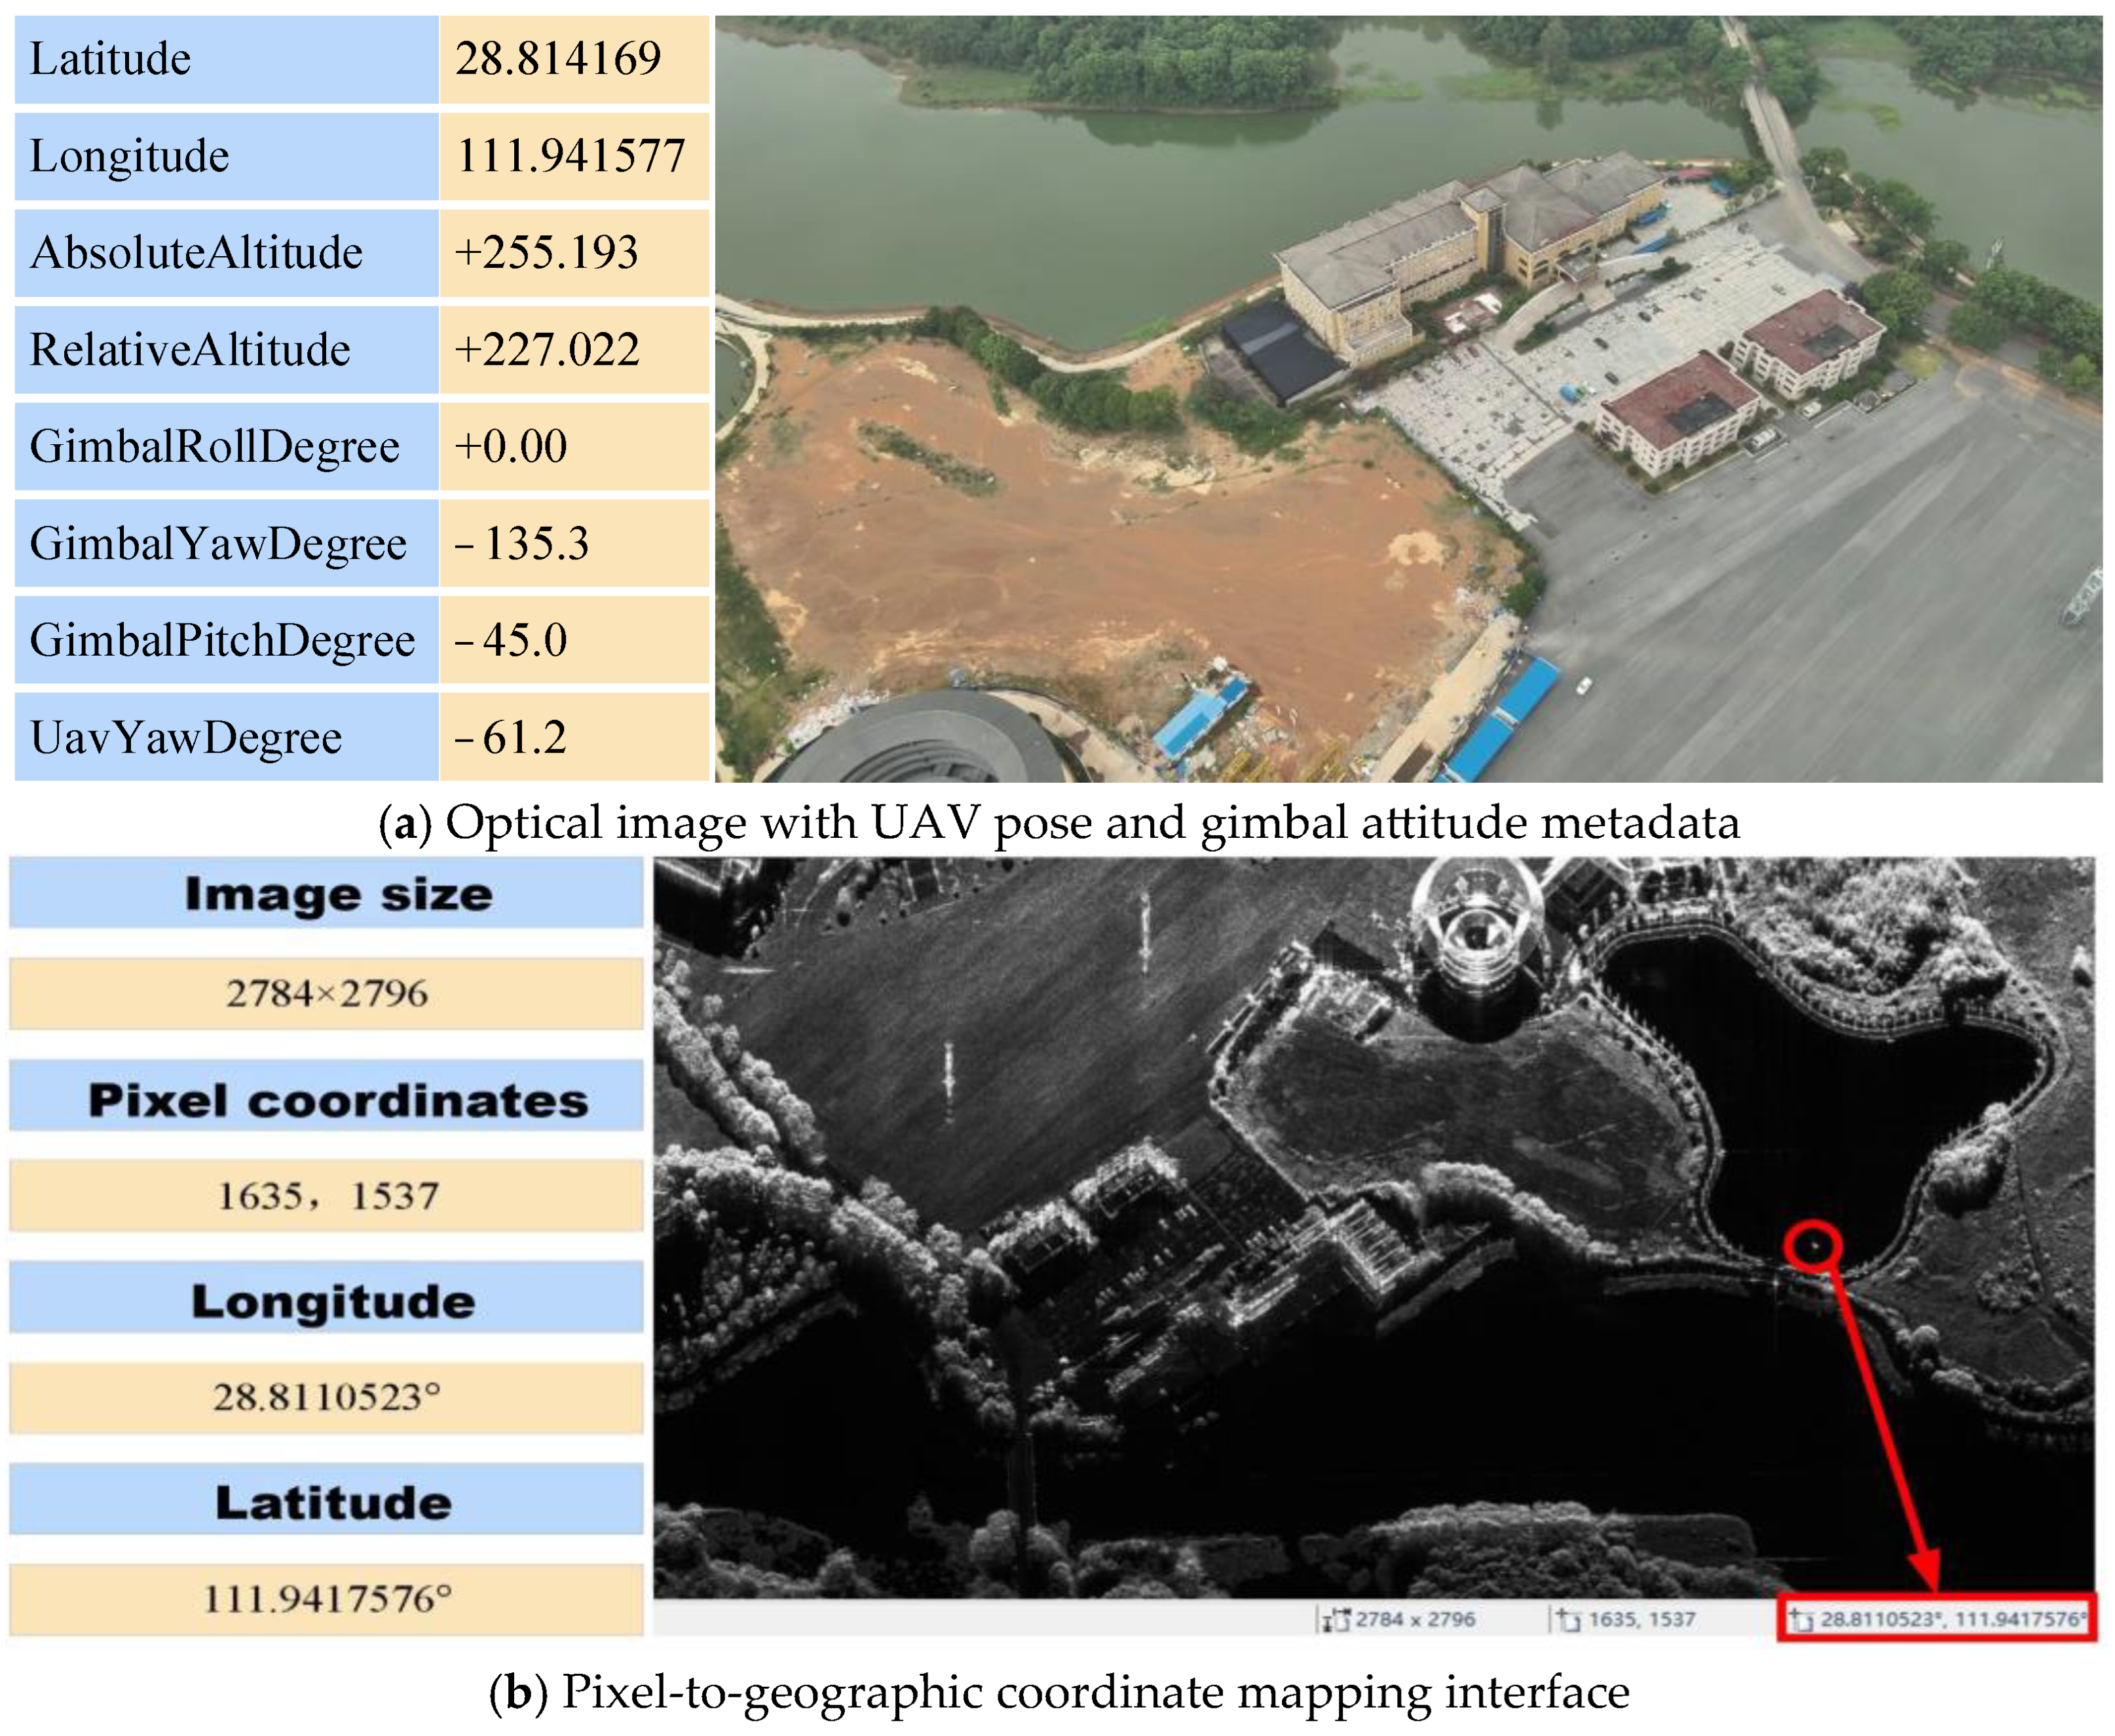
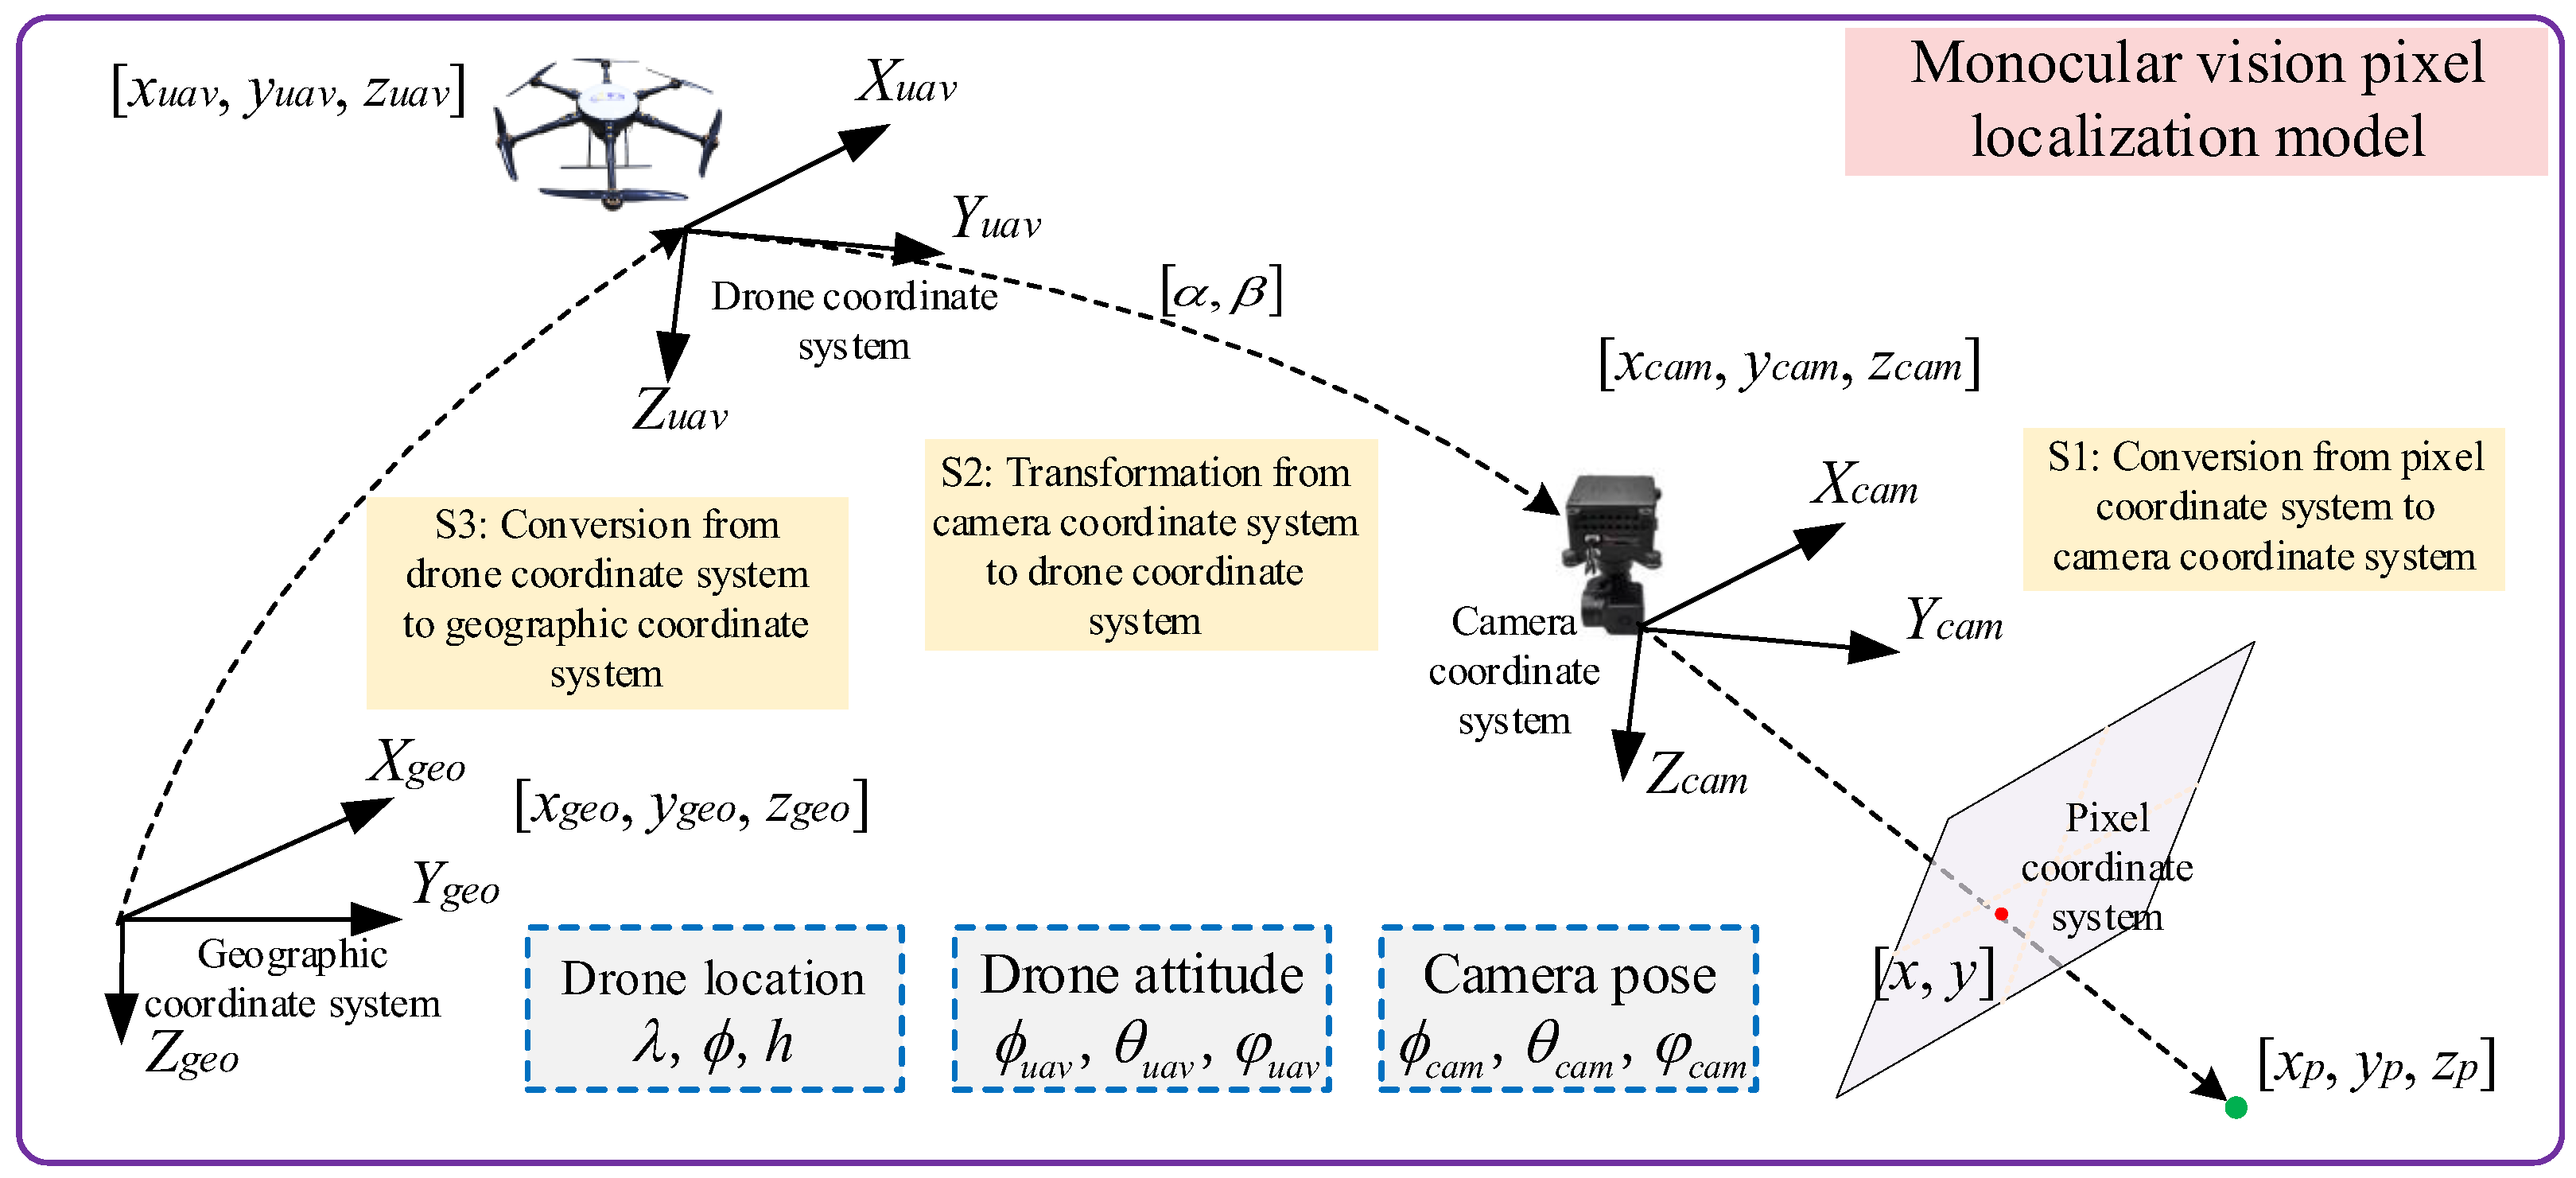
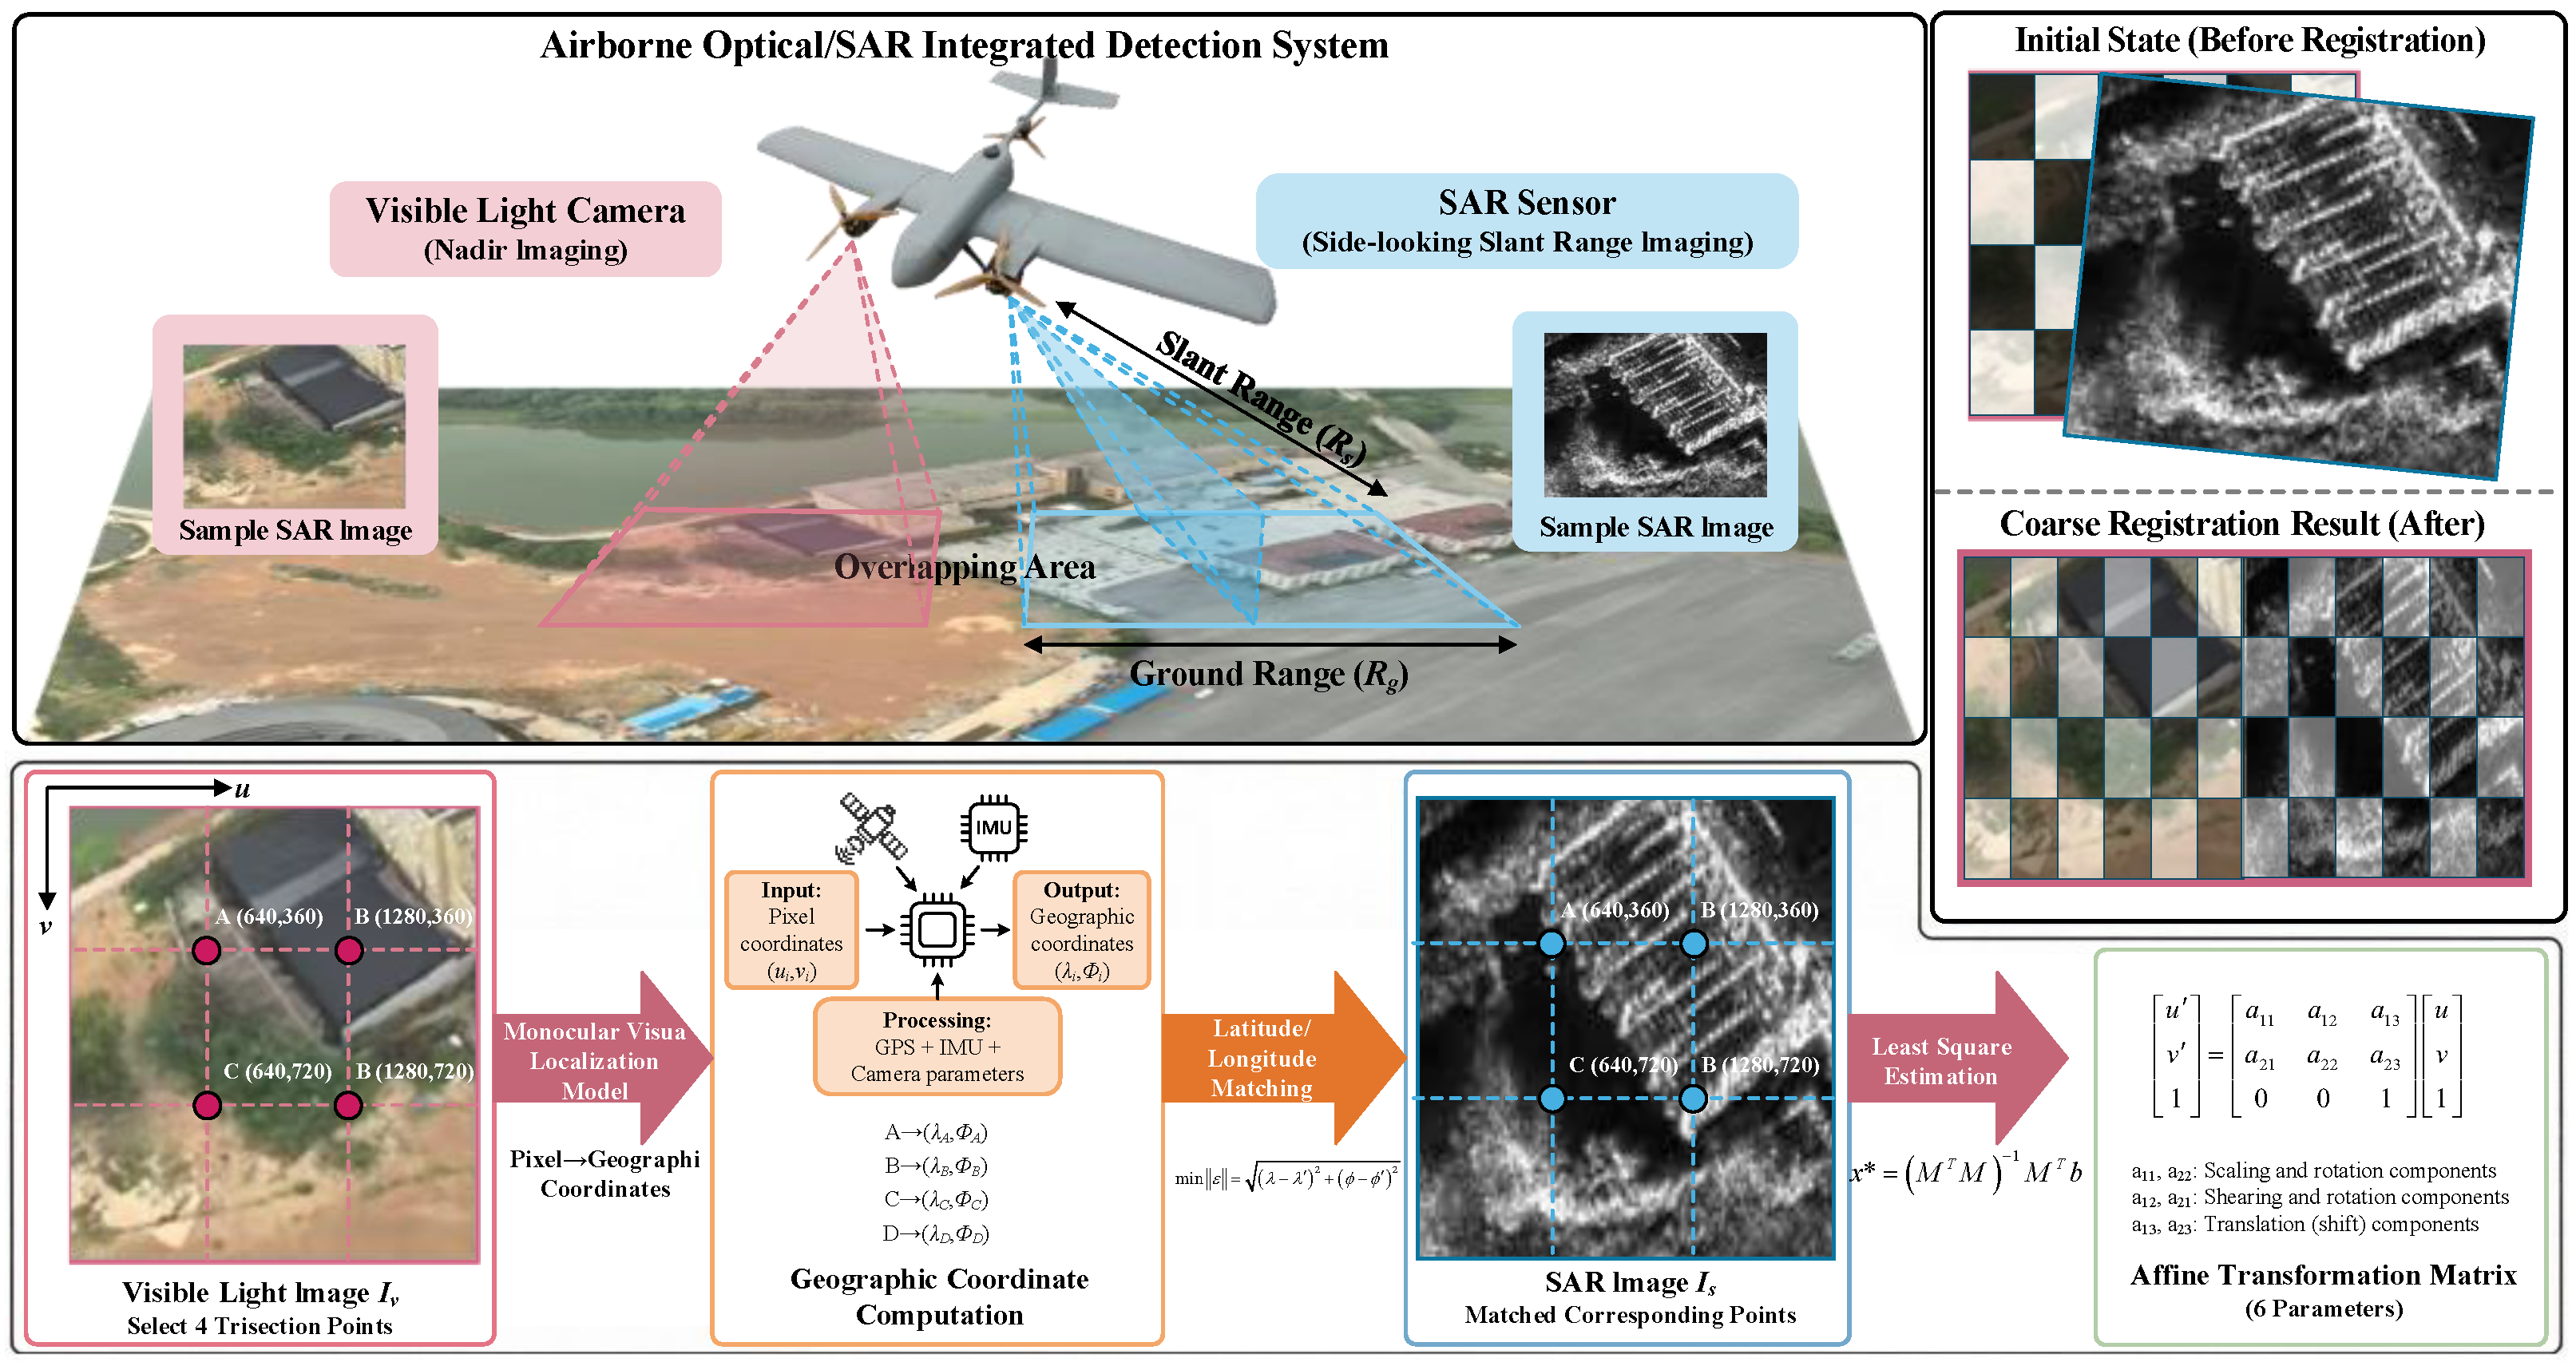
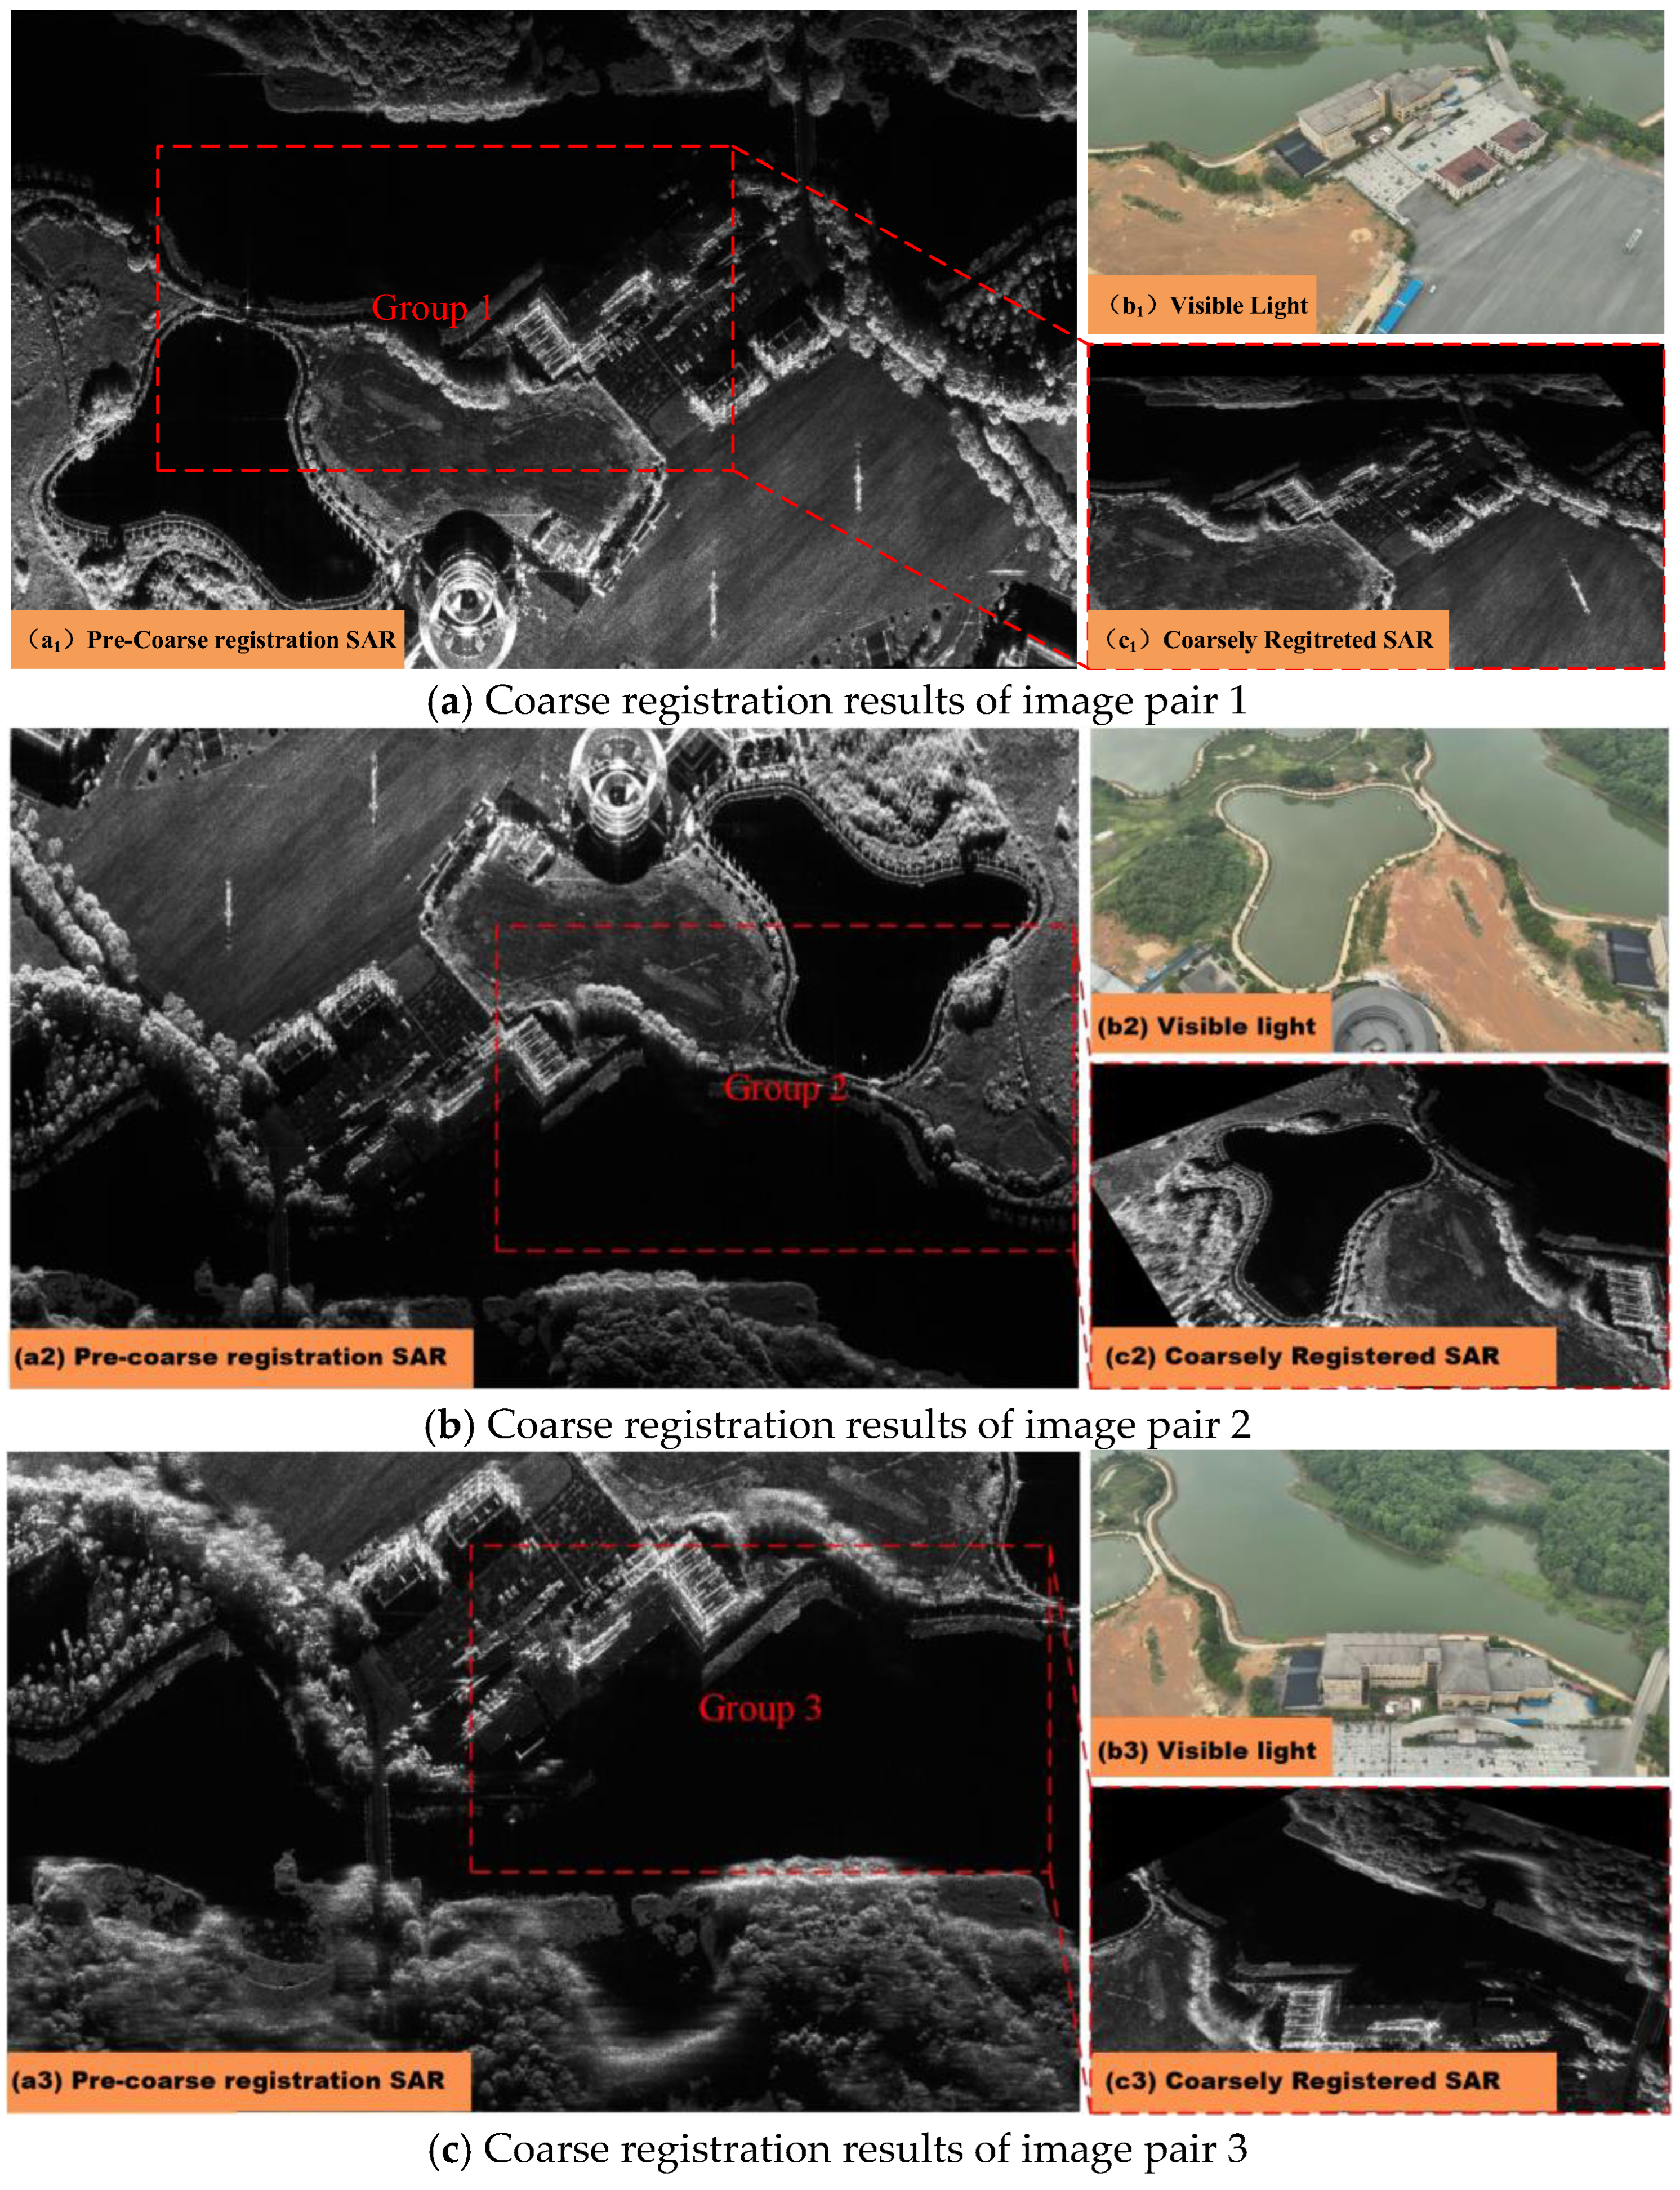
- A geographic information-constrained coarse registration strategy is proposed, which leverages imaging geometry-based coordinate transformation with UAV pose data to establish initial correspondence between images, effectively eliminating most scale differences and rotation deviations. This strategy reduces the matching search space by orders of magnitude compared with direct global matching.
- (2)
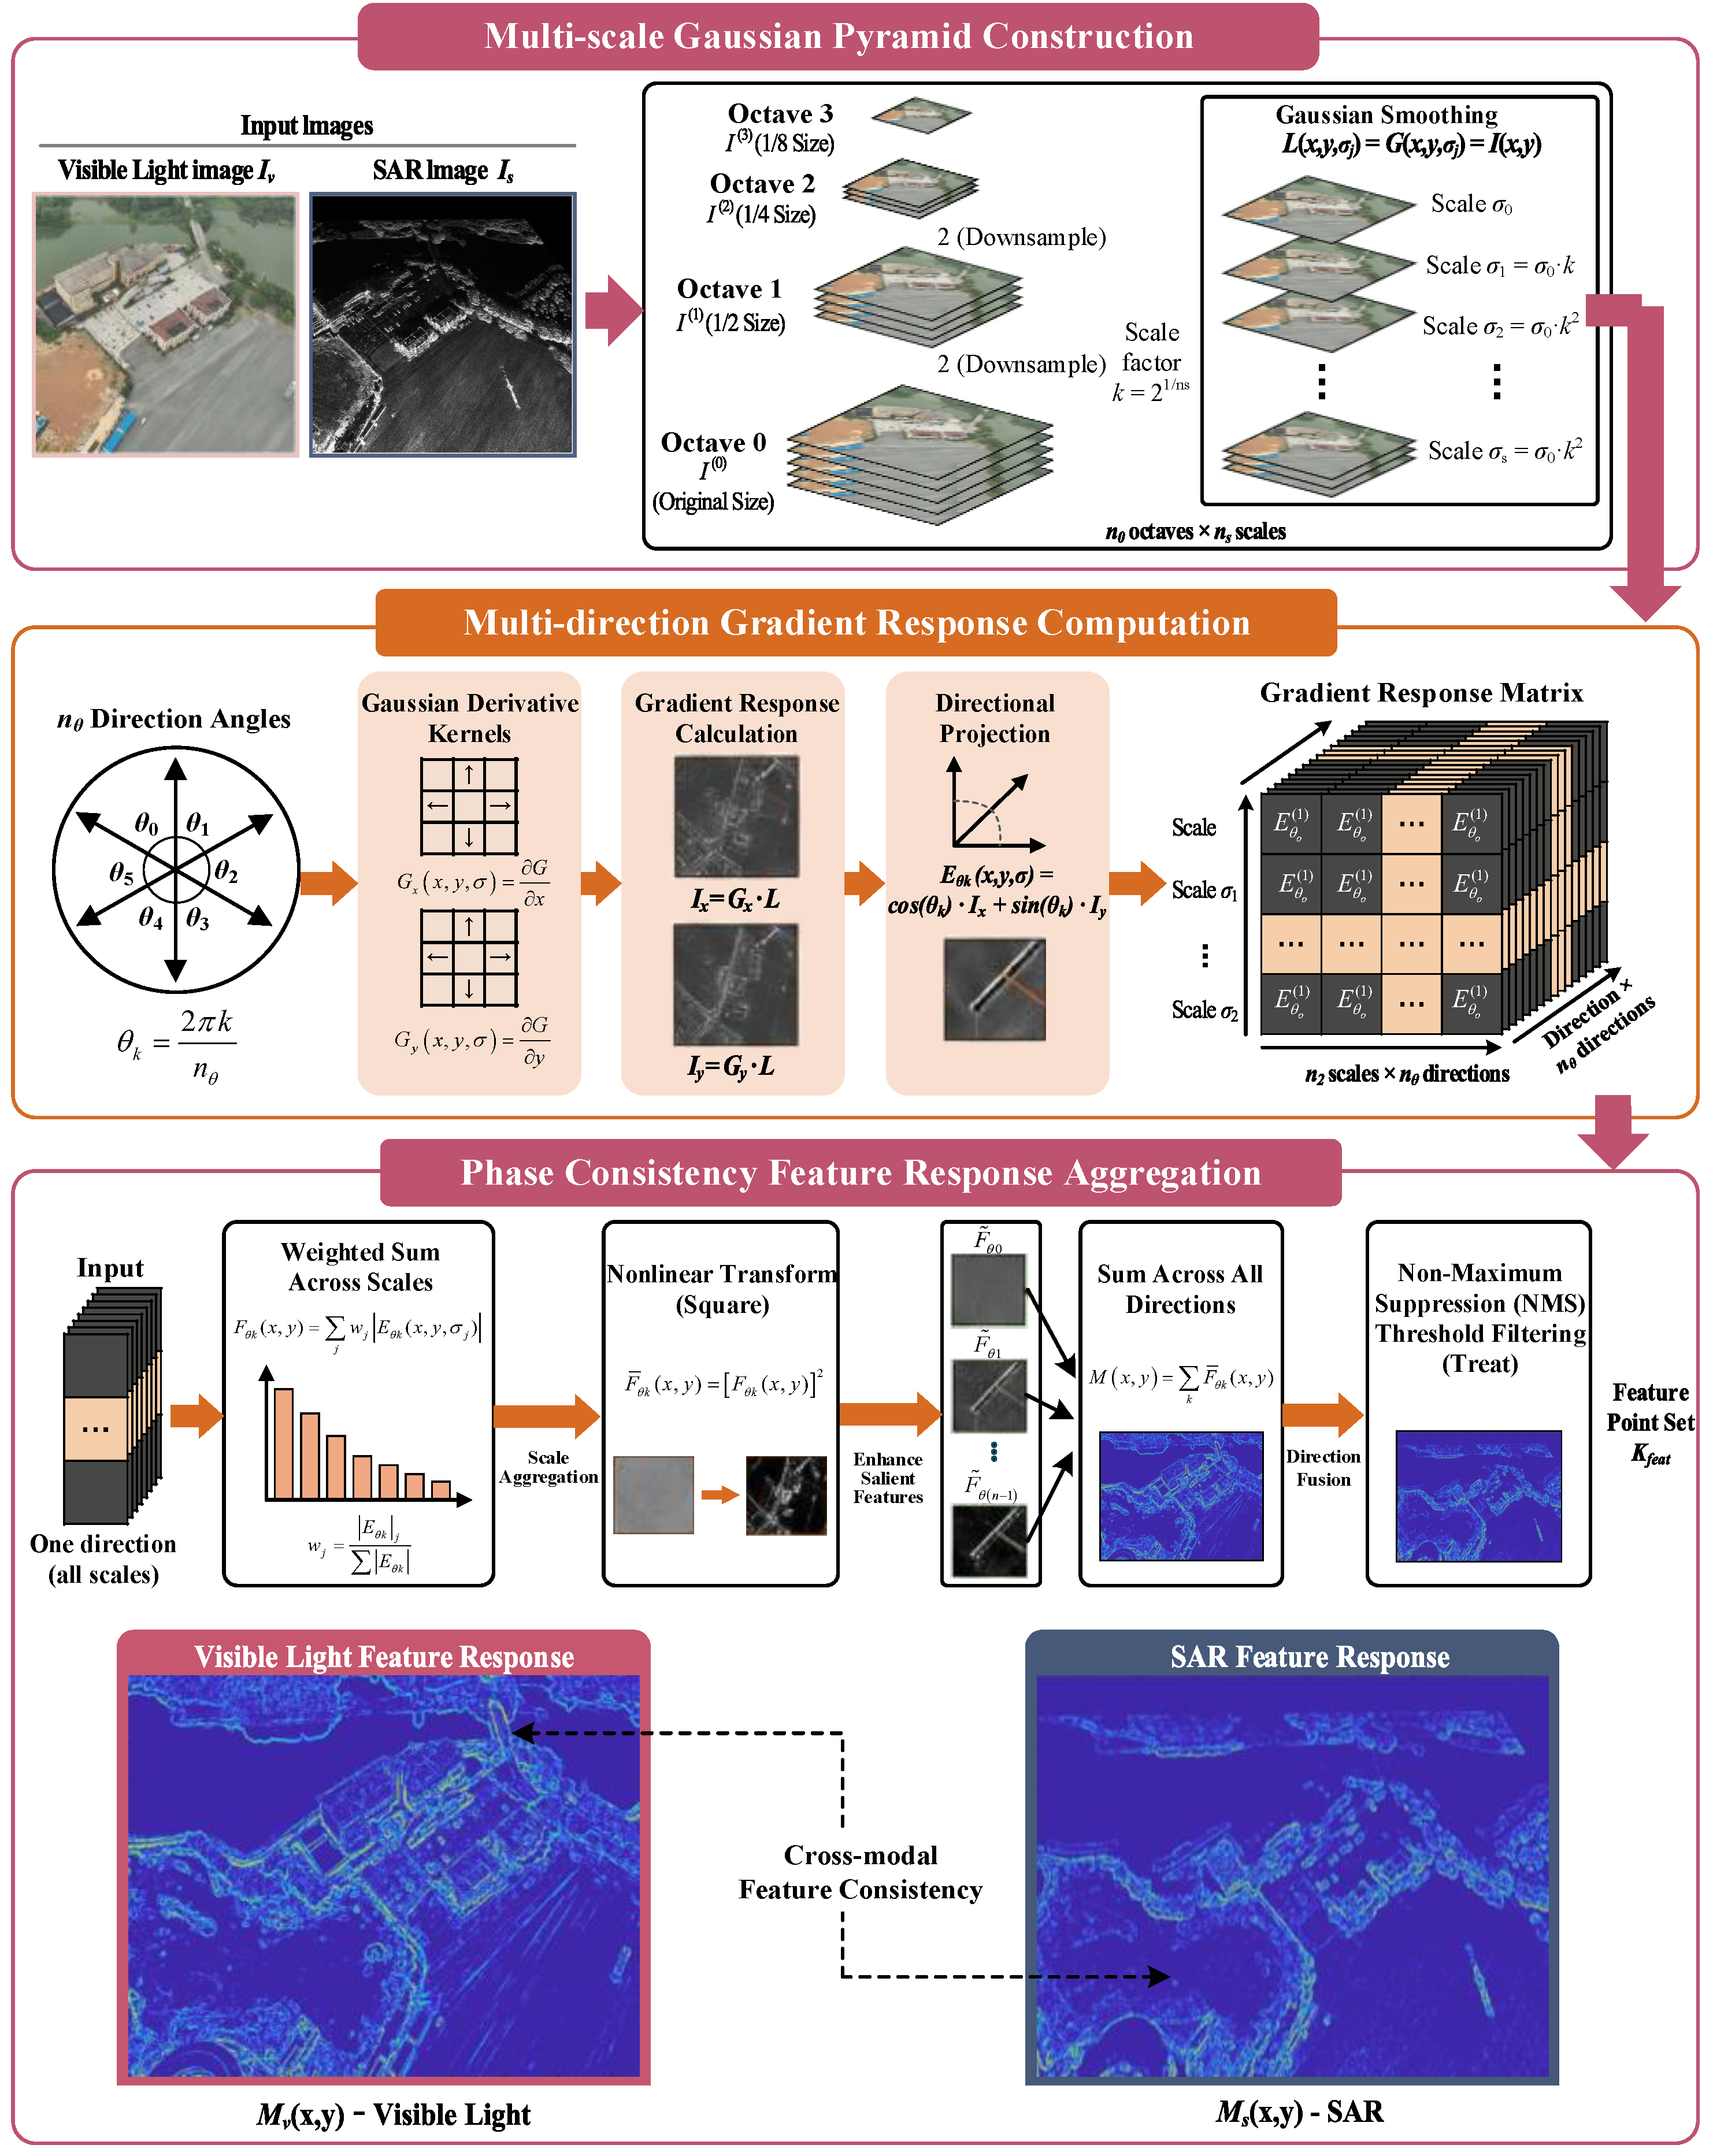
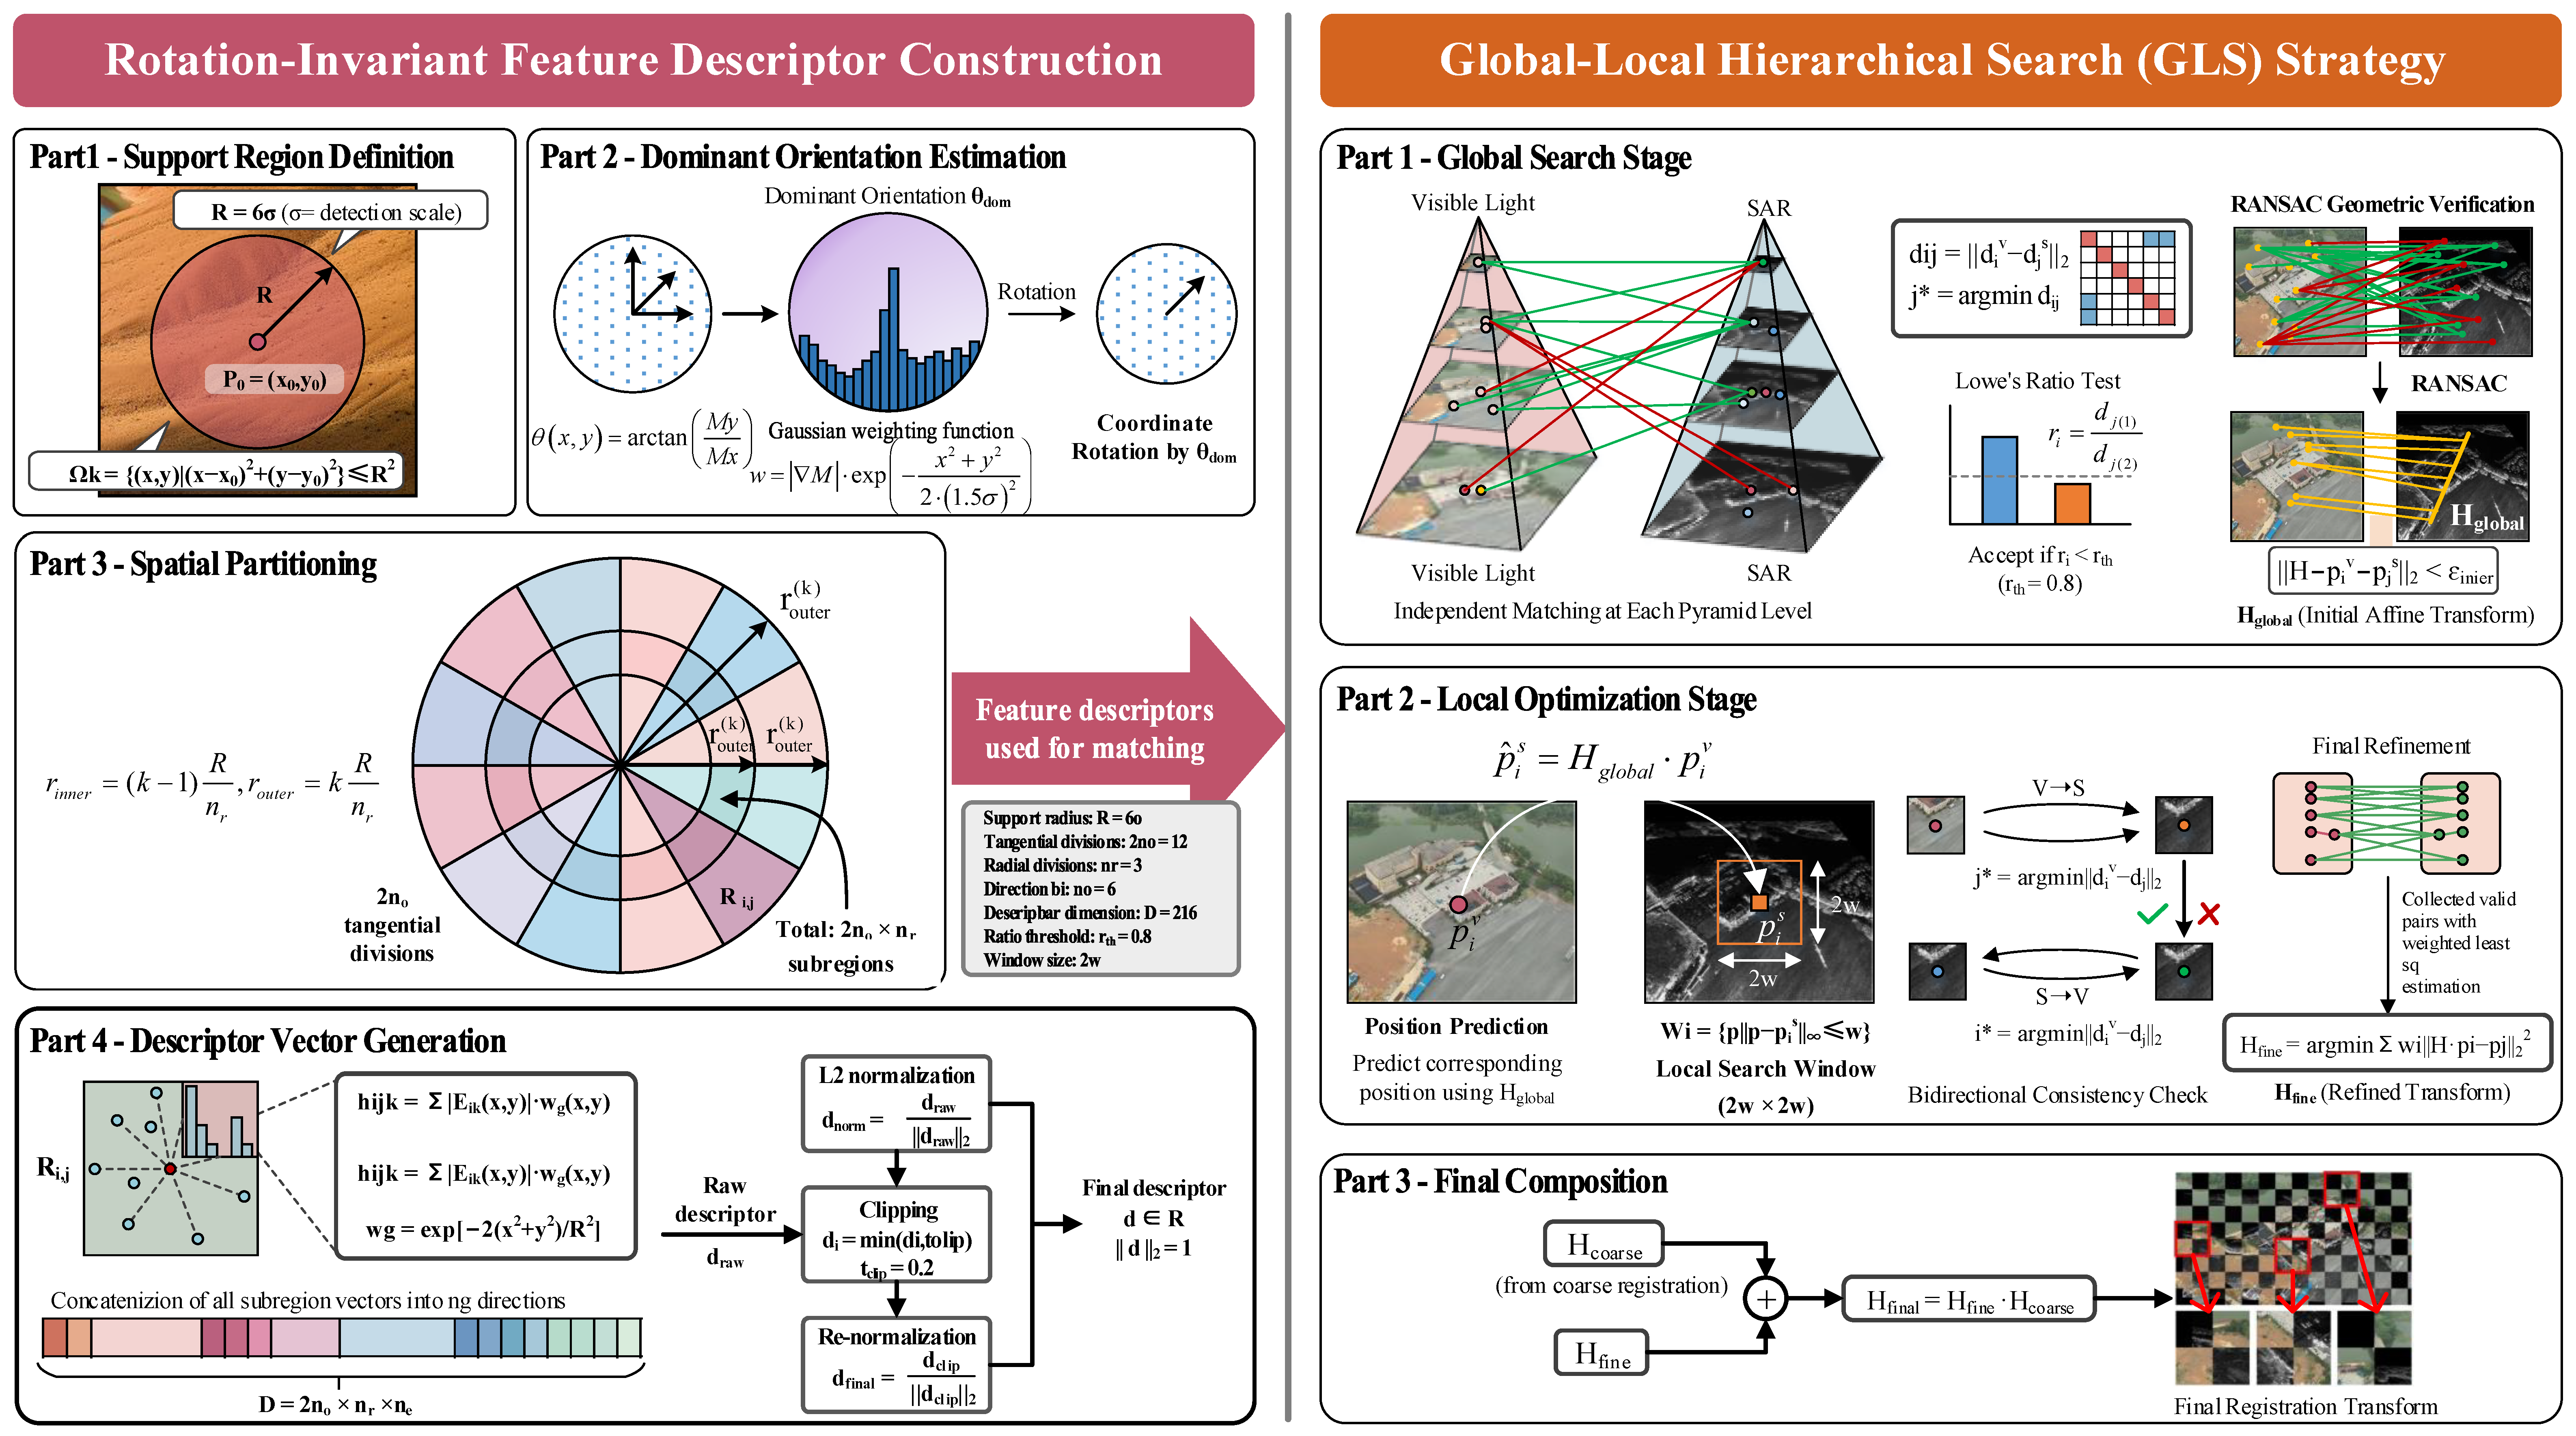
- A cross-modal feature consistency descriptor based on multi-scale Gaussian filtering and feature response aggregation is developed to overcome nonlinear radiometric differences between SAR and optical images. The descriptor exploits phase congruency theory to extract radiation-invariant structural features that exhibit consistent responses across modalities.
- (3)
- A global-to-local search (GLS) matching strategy is designed to improve matching efficiency while maintaining high accuracy. By constraining the search space using geometric predictions from coarse registration, the GLS strategy achieves 37% reduction in computational time compared with exhaustive search methods.
- (4)
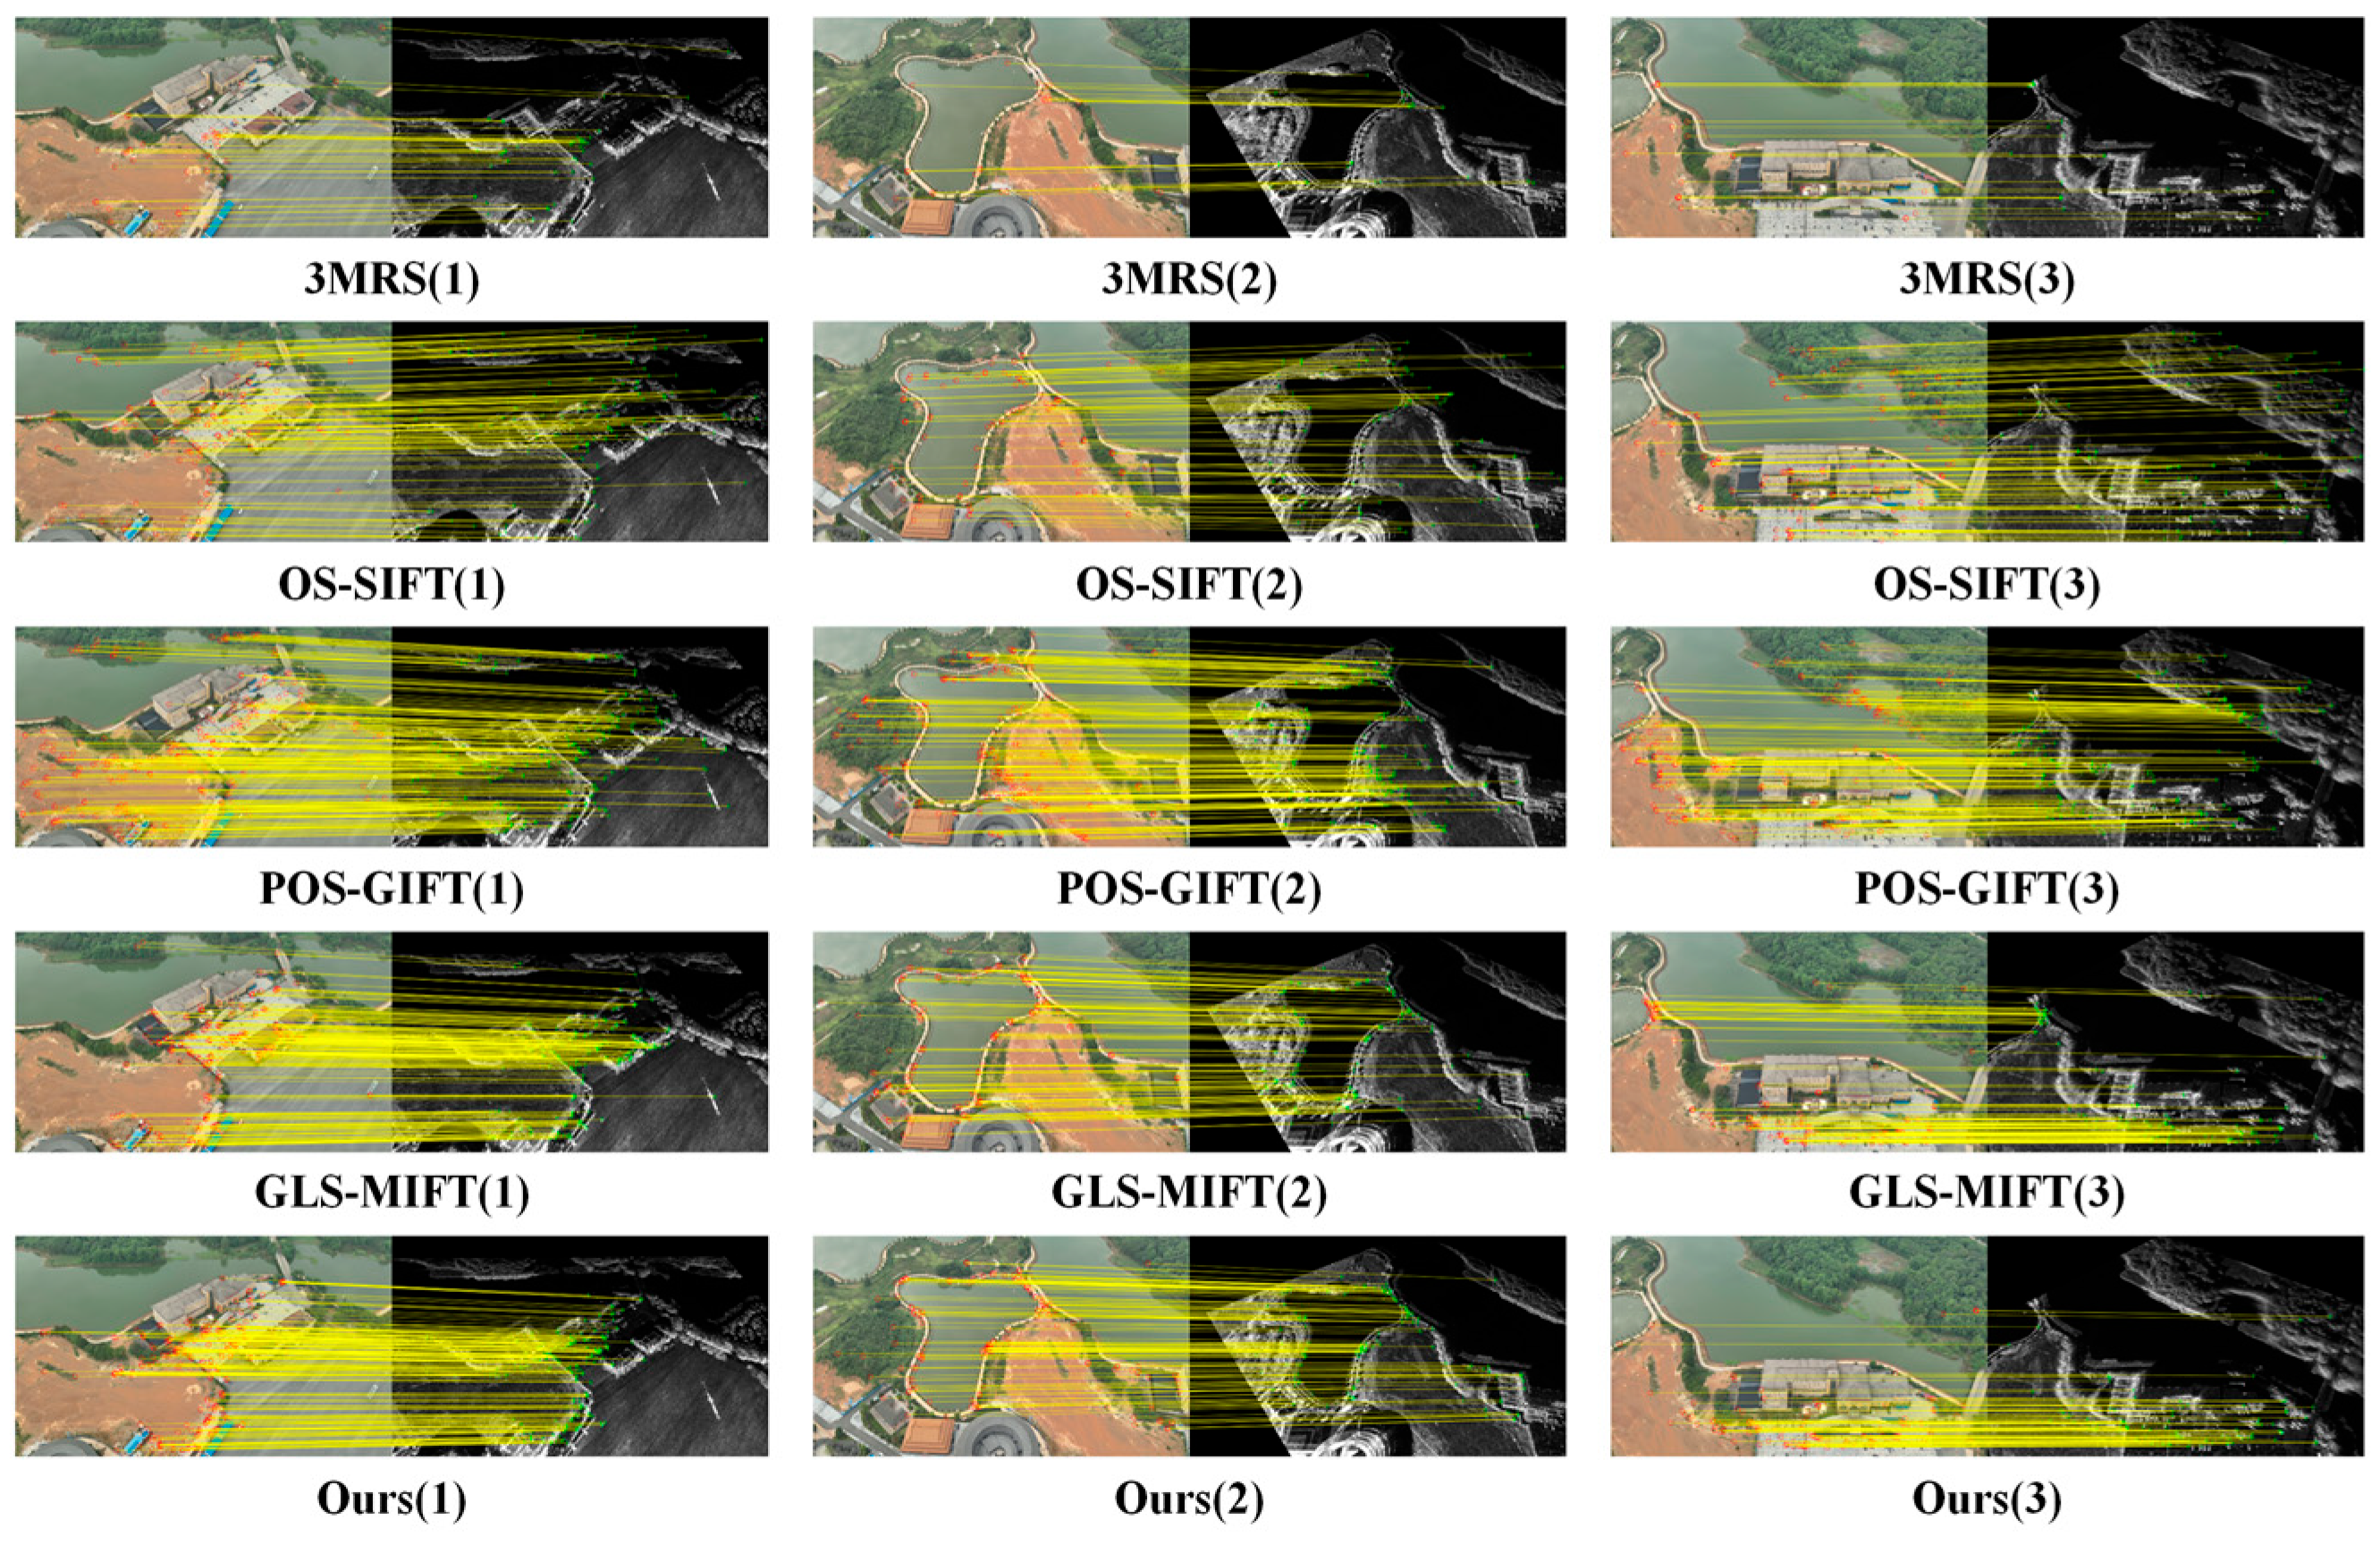
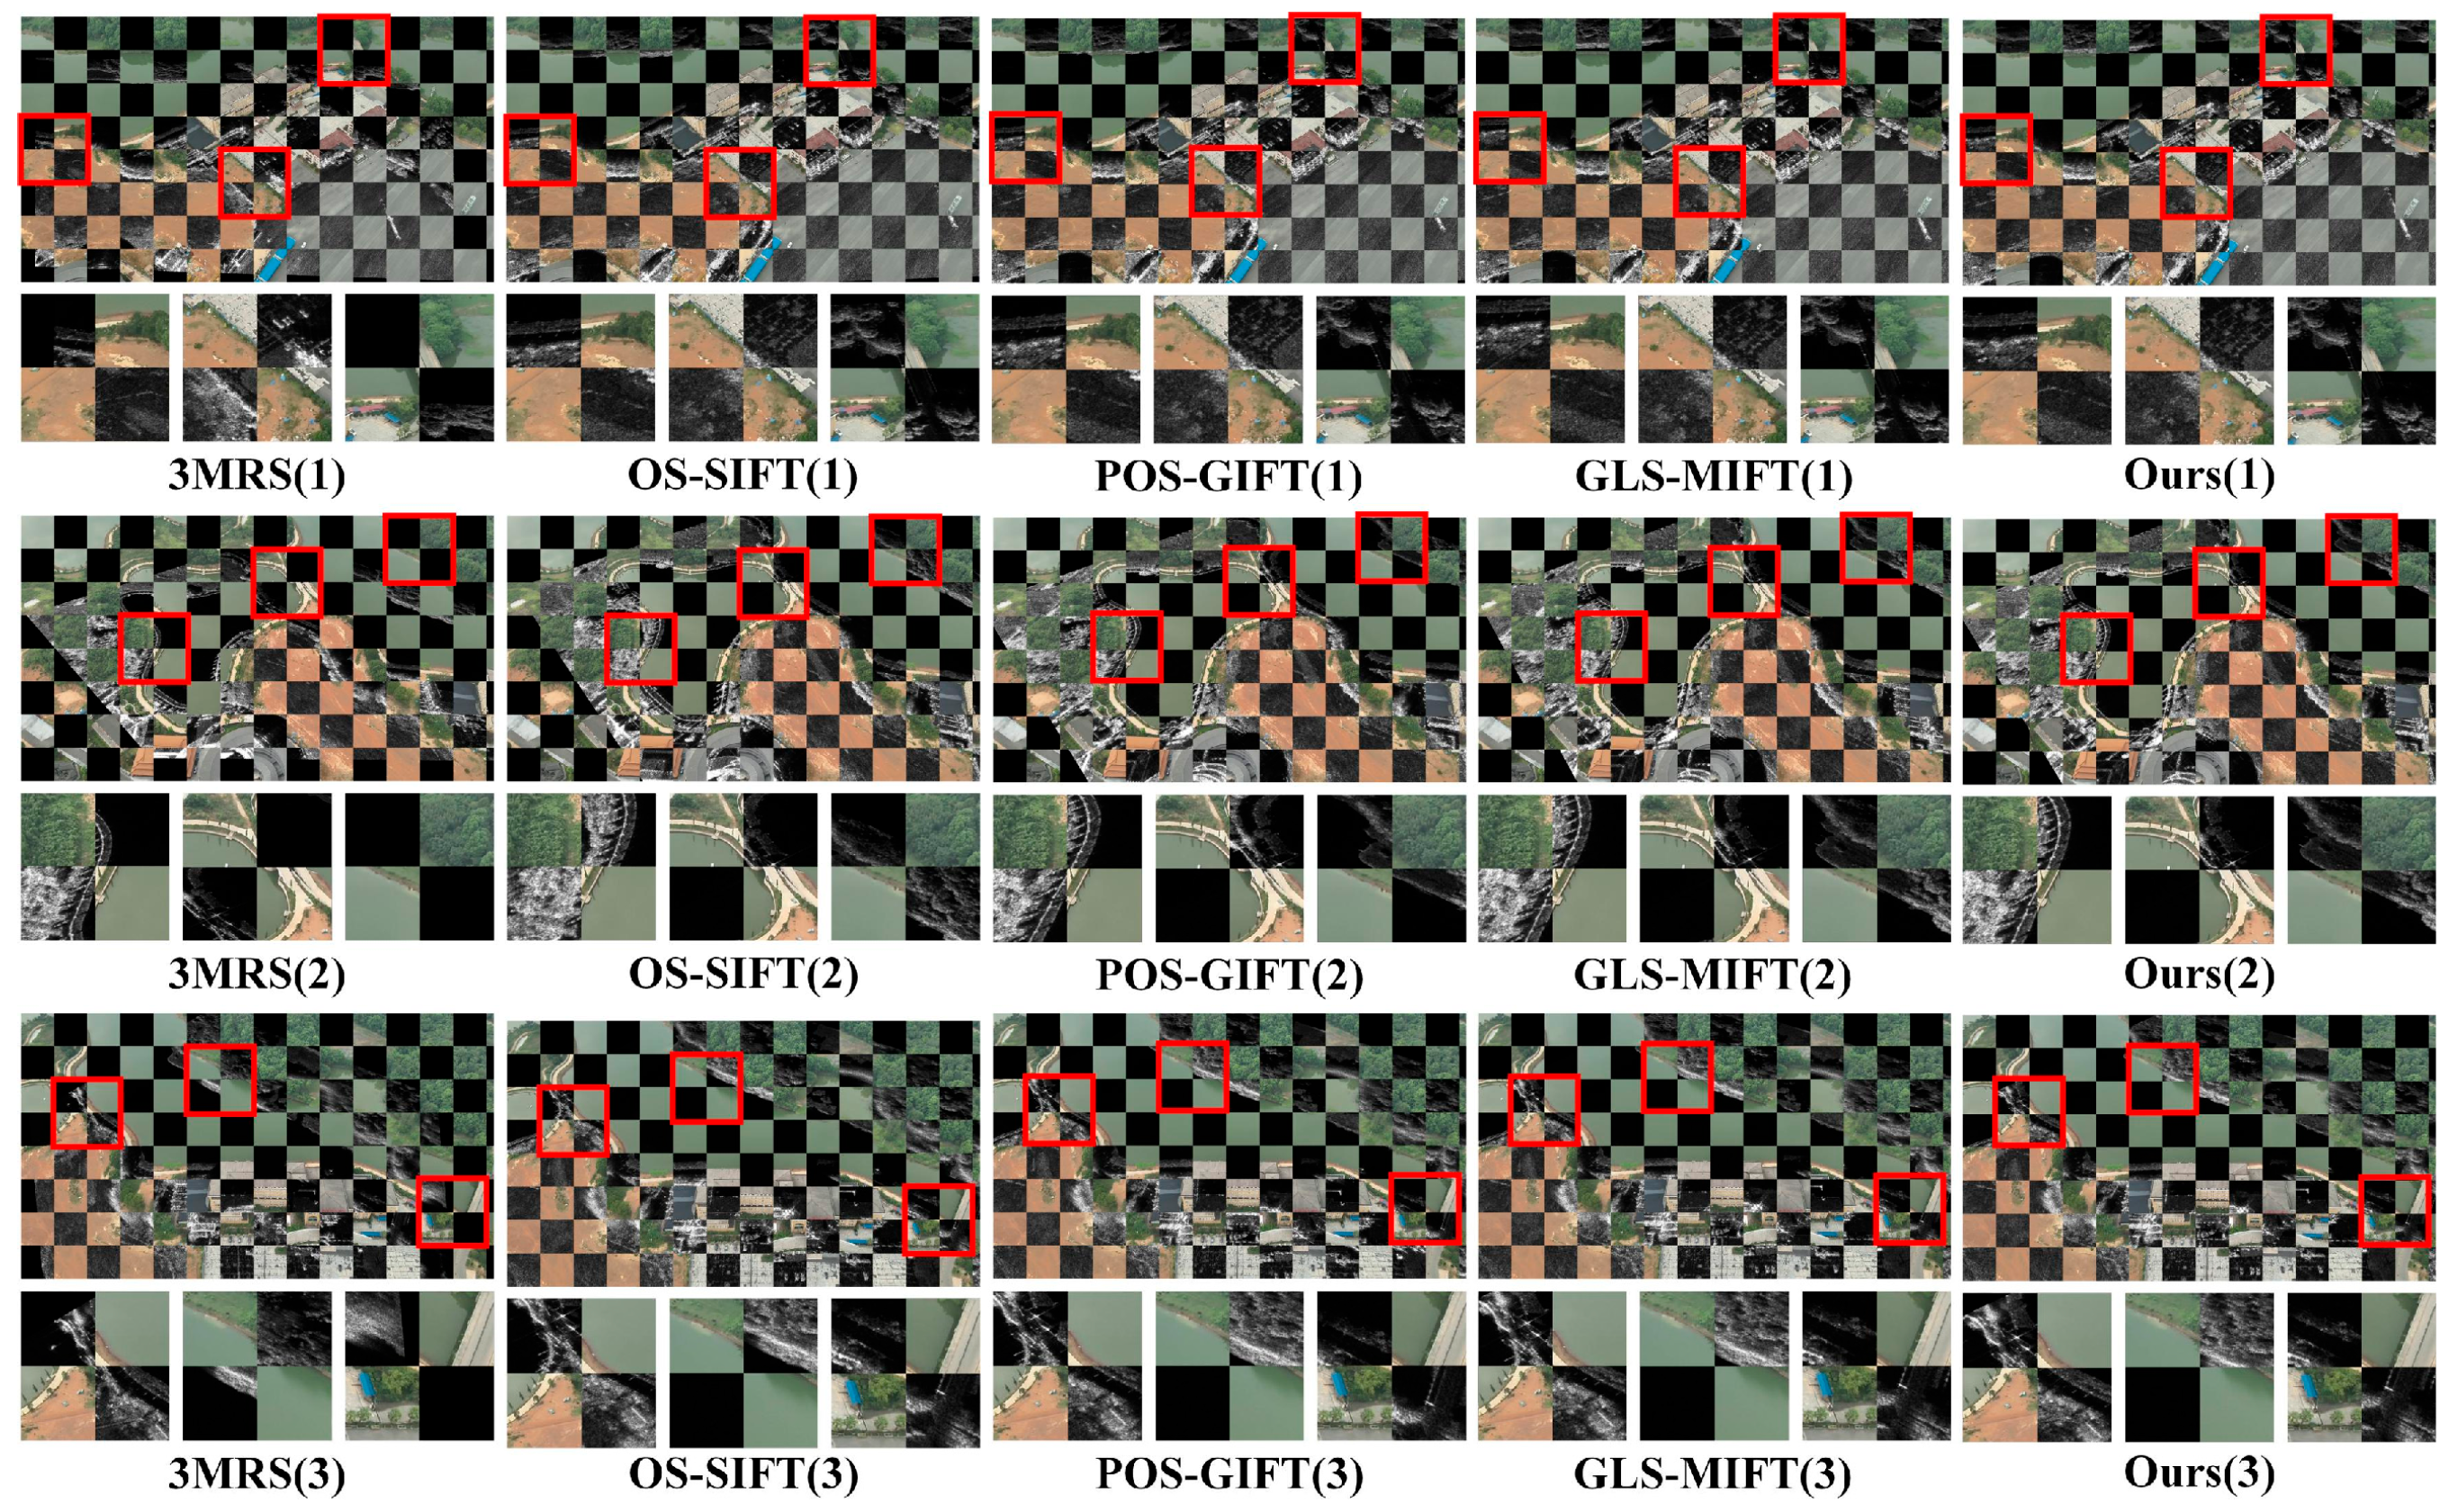
- Comprehensive experimental validation demonstrates the effectiveness of the proposed algorithm, showing superior performance compared with state-of-the-art methods, including both traditional handcrafted feature methods (3MRS, OS-SIFT, POS-GIFT, GLS-MIFT) and deep learning-based approaches, with an average RMSE of 2.0042 pixels on integrated airborne optical/SAR datasets.
2. Related Works
2.1. Area-Based Registration Methods with Similarity Metrics
2.2. Feature-Based Registration Methodss
2.3. Geographic Information Constraints for UAV-Based Registration
3. Methodology
3.1. Coarse Registration via Imaging Geometry-Based Coordinate Transformation with Geographic Information Constraints
3.2. Multi-Scale Feature Response Aggregation Based on Phase Congruency
3.3. Rotation-Invariant Feature Descriptor and Global-to-Local Hierarchical Search
4. Experiments
4.1. Experimental Setup
4.1.1. Dataset
4.1.2. Implementation Details
4.1.3. Evaluation Metrics
4.2. Coarse Registration Experiments
4.3. Fine Registration Experiments
4.4. Ablation Studies
4.4.1. Coarse Registration Stage Ablation
4.4.2. Fine Registration Stage Ablation
4.4.3. Feature Descriptor Parameter Analysis
4.4.4. GLS Strategy Validation
5. Discussion
6. Conclusions
Author Contributions
Funding
Data Availability Statement
Conflicts of Interest
References
- Sommervold, O.; Gazzea, M.; Arghandeh, R. A Survey on SAR and Optical Satellite Image Registration. Remote Sens. 2023, 15, 850. [Google Scholar] [CrossRef] [Scilit]
- Zhu, B.; Zhou, L.; Pu, S.; Fan, J.; Ye, Y. Advances and Challenges in Multimodal Remote Sensing Image Registration. IEEE J. Miniat. Air Space Syst. 2023, 4, 165–174. [Google Scholar] [CrossRef] [Scilit]
- Zhang, X.; Leng, C.; Hong, Y.; Pei, Z.; Cheng, I.; Basu, A. Multimodal Remote Sensing Image Registration Methods and Advancements: A Survey. Remote Sens. 2021, 13, 5128. [Google Scholar] [CrossRef] [Scilit]
- Kulkarni, S.C.; Rege, P.P. Pixel Level Fusion Techniques for SAR and Optical Images: A Review. Inf. Fusion 2020, 59, 13–29. [Google Scholar] [CrossRef] [Scilit]
- Wang, J.; Yang, H.; He, Y.; Zheng, F.; Liu, Z.; Chen, H. An Unpaired SAR-to-Optical Image Translation Method Based on Schrödinger Bridge Network and Multi-Scale Feature Fusion. Sci. Rep. 2024, 14, 27047. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Vivone, G.; Deng, L.-J.; Deng, S.; Hong, D.; Jiang, M.; Li, C.; Li, W.; Shen, H.; Wu, X.; Xiao, J.-L.; et al. Deep Learning in Remote Sensing Image Fusion: Methods, Protocols, Data, and Future Perspectives. IEEE Geosci. Remote Sens. Mag. 2025, 13, 269–310. [Google Scholar] [CrossRef] [Scilit]
- Huang, M.; Xu, Y.; Qian, L.; Shi, W.; Zhang, Y.; Bao, W.; Wang, N.; Liu, X.; Xiang, X. A Bridge Neural Network-Based Optical-SAR Image Joint Intelligent Interpretation Framework. Space Sci. Technol. 2021, 2021, 9841456. [Google Scholar] [CrossRef] [Scilit]
- Brown, L.G. A Survey of Image Registration Techniques. ACM Comput. Surv. 1992, 24, 325–376. [Google Scholar] [CrossRef] [Scilit]
- Zitová, B.; Flusser, J. Image Registration Methods: A Survey. Image Vis. Comput. 2003, 21, 977–1000. [Google Scholar] [CrossRef] [Scilit]
- Chen, S.; Mei, L. Structure Similarity Virtual Map Generation Network for Optical and SAR Image Matching. Front. Phys. 2024, 12, 1287050. [Google Scholar] [CrossRef] [Scilit]
- Zhang, W. Robust Registration of SAR and Optical Images Based on Deep Learning and Improved Harris Algorithm. Sci. Rep. 2022, 12, 5901. [Google Scholar] [CrossRef] [Scilit]
- Yang, X.; Wang, Z.; Zhao, J.; Yang, D. FG-GAN: A Fine-Grained Generative Adversarial Network for Unsupervised SAR-to-Optical Image Translation. IEEE Trans. Geosci. Remote Sens. 2022, 60, 5621211. [Google Scholar] [CrossRef] [Scilit]
- Li, H.; Gu, C.; Wu, D.; Cheng, G.; Guo, L.; Liu, H. Multiscale Generative Adversarial Network Based on Wavelet Feature Learning for SAR-to-Optical Image Translation. IEEE Trans. Geosci. Remote Sens. 2022, 60, 5236115. [Google Scholar] [CrossRef] [Scilit]
- Zhang, K.; Yu, A.; Tong, W.; Dong, Z. A Robust SAR-Optical Heterologous Image Registration Method Based on Region-Adaptive Keypoint Selection. Remote Sens. 2024, 16, 3289. [Google Scholar] [CrossRef] [Scilit]
- Tan, S.; Duan, Z.; Pu, L. Multi-Scale Object Detection in UAV Images Based on Adaptive Feature Fusion. PLoS ONE 2024, 19, e0300120. [Google Scholar] [CrossRef] [Scilit]
- Samaras, S.; Diamantidou, E.; Ataloglou, D.; Sakellariou, N.; Vafeiadis, A.; Magoulianitis, V.; Lalas, A.; Dimou, A.; Zarpalas, D.; Votis, K.; et al. Deep Learning on Multi Sensor Data for Counter Uav Applications—A Systematic Review. Sensors 2019, 19, 4837. [Google Scholar] [CrossRef] [Scilit]
- Yao, H.; Qin, R.; Chen, X. Unmanned Aerial Vehicle for Remote Sensing Applications—A Review. Remote Sens. 2019, 11, 1443. [Google Scholar] [CrossRef] [Scilit]
- Goforth, H.; Lucey, S. GPS-Denied UAV Localization Using Pre-Existing Satellite Imagery. In Proceedings of the 2019 International Conference on Robotics and Automation, ICRA 2019, Montreal, QC, Canada, 20–24 May 2019; IEEE: New York, NY, USA, 2019; pp. 2974–2980. [Google Scholar]
- Chen, S.; Wu, X.; Mueller, M.W.; Sreenath, K. Real-Time Geo-Localization Using Satellite Imagery and Topography for Unmanned Aerial Vehicles. In Proceedings of the 2021 IEEE/RSJ International Conference on Intelligent Robots and Systems, IROS 2021, Prague, Czech Republic, 27 September–1 October 2021; IEEE: New York, NY, USA, 2021; pp. 2275–2281. [Google Scholar]
- Lowe, D.G. Distinctive Image Features from Scale-Invariant Keypoints. Int. J. Comput. Vis. 2004, 60, 91–110. [Google Scholar] [CrossRef] [Scilit]
- Bay, H.; Ess, A.; Tuytelaars, T.; Van Gool, L. Speeded-Up Robust Features (SURF). Comput. Vis. Image Underst. 2008, 110, 346–359. [Google Scholar] [CrossRef] [Scilit]
- Sedaghat, A.; Mokhtarzade, M.; Ebadi, H. Uniform Robust Scale-Invariant Feature Matching for Optical Remote Sensing Images. IEEE Trans. Geosci. Remote Sens. 2011, 49, 4516–4527. [Google Scholar] [CrossRef] [Scilit]
- Mikolajczyk, K.; Schmid, C. A Performance Evaluation of Local Descriptors. IEEE Trans. Pattern Anal. Mach. Intell. 2005, 27, 1615–1630. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Zhang, W.; Zhao, Y. An Improved SIFT Algorithm for Registration between SAR and Optical Images. Sci. Rep. 2023, 13, 6346. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Ye, Y.; Shan, J.; Bruzzone, L.; Shen, L. Robust Registration of Multimodal Remote Sensing Images Based on Structural Similarity. IEEE Trans. Geosci. Remote Sens. 2021, 55, 2941–2958. [Google Scholar] [CrossRef] [Scilit]
- Kovesi, P. Image Features from Phase Congruency. J. Comput. Vis. Res. 1995, 1, 1–26. [Google Scholar]
- Ma, W.; Wu, Y.; Liu, S.; Su, Q.; Zhong, Y. Remote Sensing Image Registration Based on Phase Congruency Feature Detection and Spatial Constraint Matching. IEEE Access 2018, 6, 77554–77567. [Google Scholar] [CrossRef] [Scilit]
- Fan, B.; Wu, F.; Hu, Z. Rotationally Invariant Descriptors Using Intensity Order Pooling. IEEE Trans. Pattern Anal. Mach. Intell. 2012, 34, 2031–2045. [Google Scholar] [CrossRef] [Scilit]
- Ma, J.; Jiang, X.; Fan, A.; Jiang, J.; Yan, J. Image Matching From Handcrafted to Deep Features: A Survey. Int. J. Comput. Vis. 2021, 129, 23–79. [Google Scholar] [CrossRef] [Scilit]
- Viola, P.; Wells, W.M. Alignment by Maximization of Mutual Information. In Proceedings of the IEEE International Conference on Computer Vision; IEEE: New York, NY, USA, 1995; pp. 16–23. [Google Scholar]
- Cole-Rhodes, A.A.; Johnson, K.L.; LeMoigne, J.; Zavorin, L. Multiresolution Registration of Remote Sensing Imagery by Optimization of Mutual Information Using a Stochastic Gradient. IEEE Trans. Image Process. 2003, 12, 1495–1510. [Google Scholar] [CrossRef]
- Pluim, J.P.W.; Maintz, J.B.A.A.; Viergever, M.A. Mutual-Information-Based Registration of Medical Images: A Survey. IEEE Trans. Med. Imaging 2003, 22, 986–1004. [Google Scholar] [CrossRef] [Scilit]
- Maes, F.; Vandermeulen, D.; Suetens, P. Comparative Evaluation of Multiresolution Optimization Strategies for Multimodality Image Registration by Maximization of Mutual Information. Med. Image Anal. 1999, 3, 373–386. [Google Scholar] [CrossRef] [Scilit]
- Suri, S.; Reinartz, P. Mutual-Information-Based Registration of TerraSAR-X and Ikonos Imagery in Urban Areas. IEEE Trans. Geosci. Remote Sens. 2010, 48, 939–949. [Google Scholar] [CrossRef] [Scilit]
- Xiong, X.; Jin, G.; Xu, Q.; Zhang, H. Robust SAR Image Registration Using Rank-Based Ratio Self-Similarity. IEEE J. Sel. Top. Appl. Earth Obs. Remote Sens. 2021, 14, 2358–2368. [Google Scholar] [CrossRef] [Scilit]
- Hel-Or, Y.; Hel-Or, H.; David, E. Matching by Tone Mapping: Photometric Invariant Template Matching. IEEE Trans. Pattern Anal. Mach. Intell. 2014, 36, 317–330. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Pallotta, L.; Giunta, G.; Clemente, C. SAR Image Registration in the Presence of Rotation and Translation: A Constrained Least Squares Approach. IEEE Geosci. Remote Sens. Lett. 2021, 18, 1595–1599. [Google Scholar] [CrossRef] [Scilit]
- Harris, C.; Stephens, M. A Combined Corner and Edge Detector. In Proceedings of the Alvey Vision Conference 1988; Alvey Vision Club: Manchester, UK, 1988; pp. 23.1–23.6. [Google Scholar]
- Ke, Y.; Sukthankar, R. PCA-SIFT: A More Distinctive Representation for Local Image Descriptors. In Proceedings of the 2004 IEEE Computer Society Conference on Computer Vision and Pattern Recognition, 2004. CVPR 2004, Washington, DC, USA, 27 June–2 July 2004; Volume 2, p. II. [Google Scholar]
- Mikolajczyk, K.; Tuytelaars, T.; Schmid, C.; Zisserman, A.; Matas, J.; Schaffalitzky, F.; Kadir, T.; Van Gool, L. A Comparison of Affine Region Detectors. Int. J. Comput. Vis. 2005, 65, 43–72. [Google Scholar] [CrossRef] [Scilit]
- Dellinger, F.; Delon, J.; Gousseau, Y.; Michel, J.; Tupin, F. SAR-SIFT: A SIFT-like Algorithm for SAR Images. IEEE Trans. Geosci. Remote Sens. 2015, 53, 453–466. [Google Scholar] [CrossRef] [Scilit]
- Xiang, Y.; Wang, F.; You, H. OS-SIFT: A Robust SIFT-Like Algorithm for High-Resolution Optical-to-SAR Image Registration in Suburban Areas. IEEE Trans. Geosci. Remote Sens. 2018, 56, 3078–3090. [Google Scholar] [CrossRef] [Scilit]
- Fan, J.; Wu, Y.; Wang, F.; Zhang, Q.; Liao, G.; Li, M. SAR Image Registration Using Phase Congruency and Nonlinear Diffusion-Based SIFT. IEEE Geosci. Remote Sens. Lett. 2015, 12, 562–566. [Google Scholar] [CrossRef] [Scilit]
- Kovesi, P. Phase Congruency Detects Corners and Edges. In Digital Image Computing: Techniques and Applications 2003; CSIRO: Sydney, Australia, 2003. [Google Scholar]
- Li, J.; Hu, Q.; Ai, M. RIFT: Multi-Modal Image Matching Based on Radiation-Variation Insensitive Feature Transform. IEEE Trans. Image Process. 2020, 29, 3296–3310. [Google Scholar] [CrossRef] [Scilit]
- Li, J.; Shi, P.; Hu, Q.; Zhang, Y. RIFT2: Speeding-up RIFT with A New Rotation-Invariance Technique. arXiv 2023, arXiv:2303.00319. [Google Scholar] [CrossRef] [Scilit]
- Ye, Y.; Shan, J.; Hao, S.; Bruzzone, L.; Qin, Y. A Local Phase Based Invariant Feature for Remote Sensing Image Matching. ISPRS J. Photogramm. Remote Sens. 2018, 142, 205–221. [Google Scholar] [CrossRef] [Scilit]
- Aguilera, C.A.; Aguilera, F.J.; Sappa, A.D.; Toledo, R. Learning Cross-Spectral Similarity Measures with Deep Convolutional Neural Networks. In Proceedings of the 29th IEEE Conference on Computer Vision and Pattern Recognition Workshops, CVPRW 2016, Las Vegas, NV, USA, 26 June–1 July 2016; IEEE Computer Society: New York, NY, USA, 2016; pp. 267–275. [Google Scholar]
- Fernández Alcantarilla, P.; Bartoli, A.; Davison, A. KAZE Features. In Proceedings of the 12th European Conference on Computer Vision, ECCV 2012, Florence, Italy, 7–13 October 2012; Springer: Berlin/Heidelberg, Germany, 2012; pp. 214–227. [Google Scholar]
- Alcantarilla, P.F.; Nuevo, J.; Bartoli, A. Fast Explicit Diffusion for Accelerated Features in Nonlinear Scale Spaces. In Proceedings of the 24th British Machine Vision Conference, BMVC 2013, Bristol, UK, 9–13 September 2013; British Machine Vision Association, BMVA: Bristol, UK, 2013. [Google Scholar]
- Wang, B.; Zhang, J.; Lu, L.; Huang, G.; Zhao, Z. A Uniform SIFT-Like Algorithm for SAR Image Registration. IEEE Geosci. Remote Sens. Lett. 2015, 12, 1426–1430. [Google Scholar] [CrossRef] [Scilit]
- Soleimani, P.; Capson, D.W.; Li, K.F. Real-Time FPGA-Based Implementation of the AKAZE Algorithm with Nonlinear Scale Space Generation Using Image Partitioning. J. Real-Time Image Process. 2021, 18, 2123–2134. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Toth, C.; Jokow, G. Remote Sensing Platforms and Sensors: A Survey. ISPRS J. Photogramm. Remote Sens. 2016, 115, 22–36. [Google Scholar] [CrossRef] [Scilit]
- Colomina, I.; Molina, P. Unmanned Aerial Systems for Photogrammetry and Remote Sensing: A review. ISPRS J. Photogramm. Remote Sens. 2014, 92, 79–97. [Google Scholar] [CrossRef] [Scilit]
- Zhuo, X.; Koch, T.; Kurz, F.; Fraundorfer, F.; Reinartz, P. Automatic UAV Image Geo-Registration by Matching UAV Images to Georeferenced Image Data. Remote Sens. 2017, 9, 376. [Google Scholar] [CrossRef] [Scilit]
- Yue, K. Multi-Sensor Data Fusion for Autonomous Flight of Unmanned Aerial Vehicles in Complex Flight Environments. Drone Syst. Appl. 2024, 12, 1–12. [Google Scholar] [CrossRef] [Scilit]
- Yao, F.; Lan, C.; Wang, L.; Wan, H.; Gao, T.; Wei, Z. GNSS-Denied Geolocalization of UAVs Using Terrain-Weighted Constraint Optimization. Int. J. Appl. Earth Obs. Geoinf. 2024, 135, 104277. [Google Scholar] [CrossRef] [Scilit]
- Qiu, X.; Liao, S.; Yang, D.; Li, Y.; Wang, S. High-Precision Visual Geo-Localization of UAV Based on Hierarchical Localization. Expert Syst. Appl. 2025, 267, 126064. [Google Scholar] [CrossRef] [Scilit]
- Ye, Q.; Luo, J.; Lin, Y. A Coarse-to-Fine Visual Geo-Localization Method for GNSS-Denied UAV with Oblique-View Imagery. ISPRS J. Photogramm. Remote Sens. 2024, 212, 306–322. [Google Scholar] [CrossRef] [Scilit]
- Li, L.; Han, L.; Gao, K.; He, H.; Wang, L.; Li, J. Coarse-to-Fine Matching via Cross Fusion of Satellite Images. Int. J. Appl. Earth Obs. Geoinf. 2023, 125, 103574. [Google Scholar] [CrossRef] [Scilit]
- Sarlin, P.-E.; Cadena, C.; Siegwart, R.; Dymczyk, M. From Coarse to Fine: Robust Hierarchical Localization at Large Scale. In Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition, Salt Lake City, UT, USA, 18–23 June 2018. [Google Scholar]
- Cui, Z.; Zhou, P.; Wang, X.; Zhang, Z.; Li, Y.; Li, H.; Zhang, Y. A Novel Geo-Localization Method for UAV and Satellite Images Using Cross-View Consistent Attention. Remote Sens. 2023, 15, 4667. [Google Scholar] [CrossRef] [Scilit]
- Qiu, X.; Yang, D.; Liao, S.; Wang, S.; Li, Y. Image Moment Extraction Based Aerial Photo Selection for UAV High-Precision Geolocation without GPS. Meas. J. Int. Meas. Confed. 2024, 226, 114141. [Google Scholar] [CrossRef] [Scilit]
- Novikov, D.; Sotirelis, P.; Yilmaz, A. Vehicle Geolocalization from Drone Imagery. ISPRS Ann. Photogramm. Remote Sens. Spat. Inf. Sci. 2024, 10, 171–178. [Google Scholar] [CrossRef] [Scilit]
- Li, A.; Cheng, X.; Guan, H.; Feng, T.; Guan, Z. Novel Image Registration Method Based on Local Structure Constraints. IEEE Geosci. Remote Sens. Lett. 2014, 11, 1584–1588. [Google Scholar] [CrossRef] [Scilit]





| Method Pair | Mean RMSE Difference (Pixels) | RMSE Standard Deviation (Pixels) | p-Value | Significant? (p < 0.05) |
|---|---|---|---|---|
| Ours vs. POS-GIFT | 0.10 | 0.042 | 0.032 | Yes |
| Ours vs. GLS-MIFT | 0.04 | 0.035 | 0.041 | Yes |
| Ours vs. SAROptNet | 0.28 | 0.056 | 0.001 | Yes |
| Ours vs. LoFTR | 1.00 | 0.125 | <0.001 | Yes |
| Ours vs. SuperGlue | 1.29 | 0.156 | <0.001 | Yes |
| Category | Method | Group 1 CMR | Group 1 RMSE | Group 2 CMR | Group 2 RMSE | Group 3 CMR | Group 3 RMSE | Avg. CMR | Avg. RMSE |
|---|---|---|---|---|---|---|---|---|---|
| Handcrafted | 3MRS | 44/5000 | 2.68 | 24/5000 | 2.74 | 21/5000 | 2.63 | 30/5000 | 2.69 |
| OS-SIFT | 194/5000 | 2.11 | 136/5000 | 2.58 | 158/5000 | 2.13 | 163/5000 | 2.27 | |
| POS-GIFT | 291/5000 | 2.03 | 265/5000 | 2.24 | 228/5000 | 2.05 | 261/5000 | 2.10 | |
| GLS-MIFT | 251/5000 | 2.11 | 157/5000 | 2.03 | 166/5000 | 1.97 | 191/5000 | 2.04 | |
| DeepLearning | SuperGlue | 68/5000 | 3.22 | 45/5000 | 3.48 | 52/5000 | 3.18 | 55/5000 | 3.29 |
| LoFTR | 89/5000 | 2.98 | 67/5000 | 3.13 | 73/5000 | 2.88 | 76/5000 | 3.00 | |
| ReDFeat | 156/5000 | 2.45 | 124/5000 | 2.51 | 138/5000 | 2.39 | 139/5000 | 2.45 | |
| SAROptNet | 178/5000 | 2.28 | 145/5000 | 2.32 | 152/5000 | 2.25 | 158/5000 | 2.28 | |
| Ours | Ours (CPU) | 244/5000 | 2.03 | 158/5000 | 2.03 | 136/5000 | 1.95 | 179/5000 | 2.00 |
| Our (GPU-accelerated) | 268/5000 | 1.99 | 172/5000 | 1.99 | 154/5000 | 1.92 | 198/5000 | 1.97 |
| Registration Strategy | Group 1 CMR | Group 1 RMSE | Group 2 CMR | Group 2 RMSE | Group 3 CMR | Group 3 RMSE | Avg. CMR | Avg. RMSE | Avg. Time(s) |
|---|---|---|---|---|---|---|---|---|---|
| Fine Only (Ours) | 12/5000 | 4.87 | 8/5000 | 5.12 | 15/5000 | 4.65 | 12/5000 | 4.88 | 89.45 |
| SuperGlue (w/o coarse) | 68/5000 | 3.21 | 45/5000 | 3.48 | 52/5000 | 3.18 | 55/5000 | 3.29 | 2.34 |
| LoFTR (w/o coarse) | 89/5000 | 2.98 | 67/5000 | 3.12 | 73/5000 | 2.87 | 76/5000 | 2.99 | 3.56 |
| Coarse + SuperGlue | 185/5000 | 2.18 | 134/5000 | 2.24 | 121/5000 | 2.12 | 147/5000 | 2.18 | 3.12 |
| Coarse + LoFTR | 198/5000 | 2.12 | 148/5000 | 2.18 | 132/5000 | 2.08 | 159/5000 | 2.13 | 4.24 |
| Coarse + Fine (Ours) | 244/5000 | 2.02 | 158/5000 | 2.03 | 136/5000 | 1.94 | 179/5000 | 2.00 | 60.82 |
| Method | Multi-Scale Pyramid | Feature Response Aggregation | Feature Consistency Descriptor | Rotation Invariance | Avg. CMR | Avg. RMSE | Avg. Time (s) |
|---|---|---|---|---|---|---|---|
| Baseline | × | × | × | × | 85/5000 | 2.56 | 45.23 |
| +Multi-scale | √ | × | × | × | 126/5000 | 2.31 | 52.67 |
| +Aggregation | √ | √ | × | × | 158/5000 | 2.18 | 56.34 |
| +Descriptor | √ | √ | √ | × | 179/5000 | 2.00 | 60.82 |
| Complete (Ours) | √ | √ | √ | √ | 179/5000 | 2.00 | 60.82 |
| LoFTR (after coarse) | - | - | - | - | 159/5000 | 2.13 | 4.24 |
| SuperGlue (after coarse) | - | - | - | - | 147/5000 | 2.18 | 3.12 |
| Method Type | Angular Partitions | Radial Subdivisions | Avg. CMR | Avg. RMSE | Descriptor Dimension |
|---|---|---|---|---|---|
| Ours | 8 | 2 | 142/5000 | 2.23 | 96 |
| Ours | 12 | 2 | 165/5000 | 2.08 | 144 |
| Ours (Selected) | 12 | 3 | 179/5000 | 2.00 | 216 |
| Ours | 16 | 3 | 183/5000 | 1.98 | 288 |
| Ours | 16 | 4 | 186/5000 | 1.97 | 384 |
| SuperGlue | - | - | 147/5000 | 2.18 | 256 |
| LoFTR | - | - | 159/5000 | 2.13 | 256 |
| SIFT | - | - | 163/5000 | 2.27 | 128 |
| Category | Matching Strategy | Avg. CMR | Avg. RMSE | Avg. Time (s) |
|---|---|---|---|---|
| Traditional | Brute-force | 134/5000 | 2.35 | 78.45 |
| FLANN | 156/5000 | 2.18 | 52.34 | |
| GLS Strategy (Ours) | 179/5000 | 2.00 | 60.82 | |
| Learning-based | SuperGlue Matcher | 147/5000 | 2.18 | 3.12 |
| LoFTR Matcher | 159/5000 | 2.13 | 4.24 | |
| LightGlue | 152/5000 | 5.15 | 2.45 | |
| Hybrid | Coarse + LightGlue | 168/5000 | 2.07 | 3.23 |
| GLS + LightGlue Refinement | 185/5000 | 1.95 | 4.56 |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Sun, X.; Zuo, Z.; Guo, X.; Li, X.; Zhou, P.; Guo, R.; Su, S. A Coarse-to-Fine Optical-SAR Image Registration Algorithm for UAV-Based Multi-Sensor Systems Using Geographic Information Constraints and Cross-Modal Feature Consistency Mapping. Remote Sens. 2026, 18, 683. https://doi.org/10.3390/rs18050683
Sun X, Zuo Z, Guo X, Li X, Zhou P, Guo R, Su S. A Coarse-to-Fine Optical-SAR Image Registration Algorithm for UAV-Based Multi-Sensor Systems Using Geographic Information Constraints and Cross-Modal Feature Consistency Mapping. Remote Sensing. 2026; 18(5):683. https://doi.org/10.3390/rs18050683
Chicago/Turabian StyleSun, Xiaoyong, Zhen Zuo, Xiaojun Guo, Xuan Li, Peida Zhou, Runze Guo, and Shaojing Su. 2026. "A Coarse-to-Fine Optical-SAR Image Registration Algorithm for UAV-Based Multi-Sensor Systems Using Geographic Information Constraints and Cross-Modal Feature Consistency Mapping" Remote Sensing 18, no. 5: 683. https://doi.org/10.3390/rs18050683
APA StyleSun, X., Zuo, Z., Guo, X., Li, X., Zhou, P., Guo, R., & Su, S. (2026). A Coarse-to-Fine Optical-SAR Image Registration Algorithm for UAV-Based Multi-Sensor Systems Using Geographic Information Constraints and Cross-Modal Feature Consistency Mapping. Remote Sensing, 18(5), 683. https://doi.org/10.3390/rs18050683