


Abstract
The significance of developing shared road infrastructure in cities throughout the world is growing. Driven by the need to improve traffic management in ways that enhance multiple sustainability outcomes, developing the tools needed to test shared space proposals is becoming more sought after by responsible agencies. This paper reviews approaches to simulation modeling focused on representing and assessing shared spaces, culminating in a new approach presented here called the Integrated Pedestrian–Vehicle Model (IPVM)—a novel framework that combines social force models, car-following models and other algorithms from the robotics domain to better describe both mobility and activity within a shared space. The IPVM recognizes that while shared spaces are inherently multimodal, past efforts have tended to use pedestrian models as a starting point. Most consider the interaction of pedestrians with other pedestrians and static road infrastructure. Shared space models are generally microscopic models that integrate a social force model with a variety of car-following models to describe the interaction between vehicles and pedestrians. However, there is little research and few practical methodologies that address the long-range conflict avoidance between vehicles and pedestrians. This aspect is crucial for accurately representing the desire lines and pathways of pedestrians and active transport users in complex environments like shared spaces. The IPVM describes and visualizes shared road infrastructure with an absence of separating infrastructure between users and outputs. It generates metrics that can be used in conjunction with the latest evaluation approaches to gauge the sustainability credentials of shared space road proposals. Enhanced modeling of shared space solutions can lead to more effective implementation, which can potentially reduce the presence of cars, increase public and active transport use and lead to a more sustainable transport system.
1. Introduction
In the context of road infrastructure, shared space designs aim to balance the mobility of all users of a space whilst creating a place for people to congregate, socialize and be productive [1,2,3]. This is achieved by removing separating features of the infrastructure (such as lane marking, signage, curb and guttering or street clutter) and relying on the instincts of users to move safely and avoid collisions, making more room for features that positively define a place (including street furniture, vegetation/tree canopy, street frontage dining). Examples of shared space designs are prevalent across Europe, displaying successful outcomes [4]. However, these examples are generally historic in nature (developed during the 1970s/1980s or modified squares from the 16th and 17th century), and modern-day adoption has faced significant challenges, especially in meeting the needs of vulnerable road users [5,6,7].
As shared spaces equalize priority for all users and remove separation, it has the possibility of challenging road users that require priority, such as a vision-impaired person attempting to cross the road. In addition, the ‘shared’ nature of a location, where there is limited separation, results in different interactions and conflicts between users that traverse the site and those that use the location for the purposes of socializing. Therefore, it is important to develop guidelines, standards and tools that can support the design and evaluation process to inform better decision making in future implementations of shared space designs.
Simulation models—in particular operational microsimulation models—are a key tool for practitioners to conduct optioneering and scenario testing of traffic management solutions such as the implementation of shared space designs [8]. Shared space models are underpinned by the social force model [9] and combined with car following models [8,10] to define integrated operations of the road space. However, these tools do not consider the attractiveness of the shared space or its component elements and the effect this has on the movement and distribution of pedestrians within the shared space. In addition, the conditions under which the application of long-range conflict-avoidance tactics and strategies to different classes of agents that yield good results, remains an active area of research.
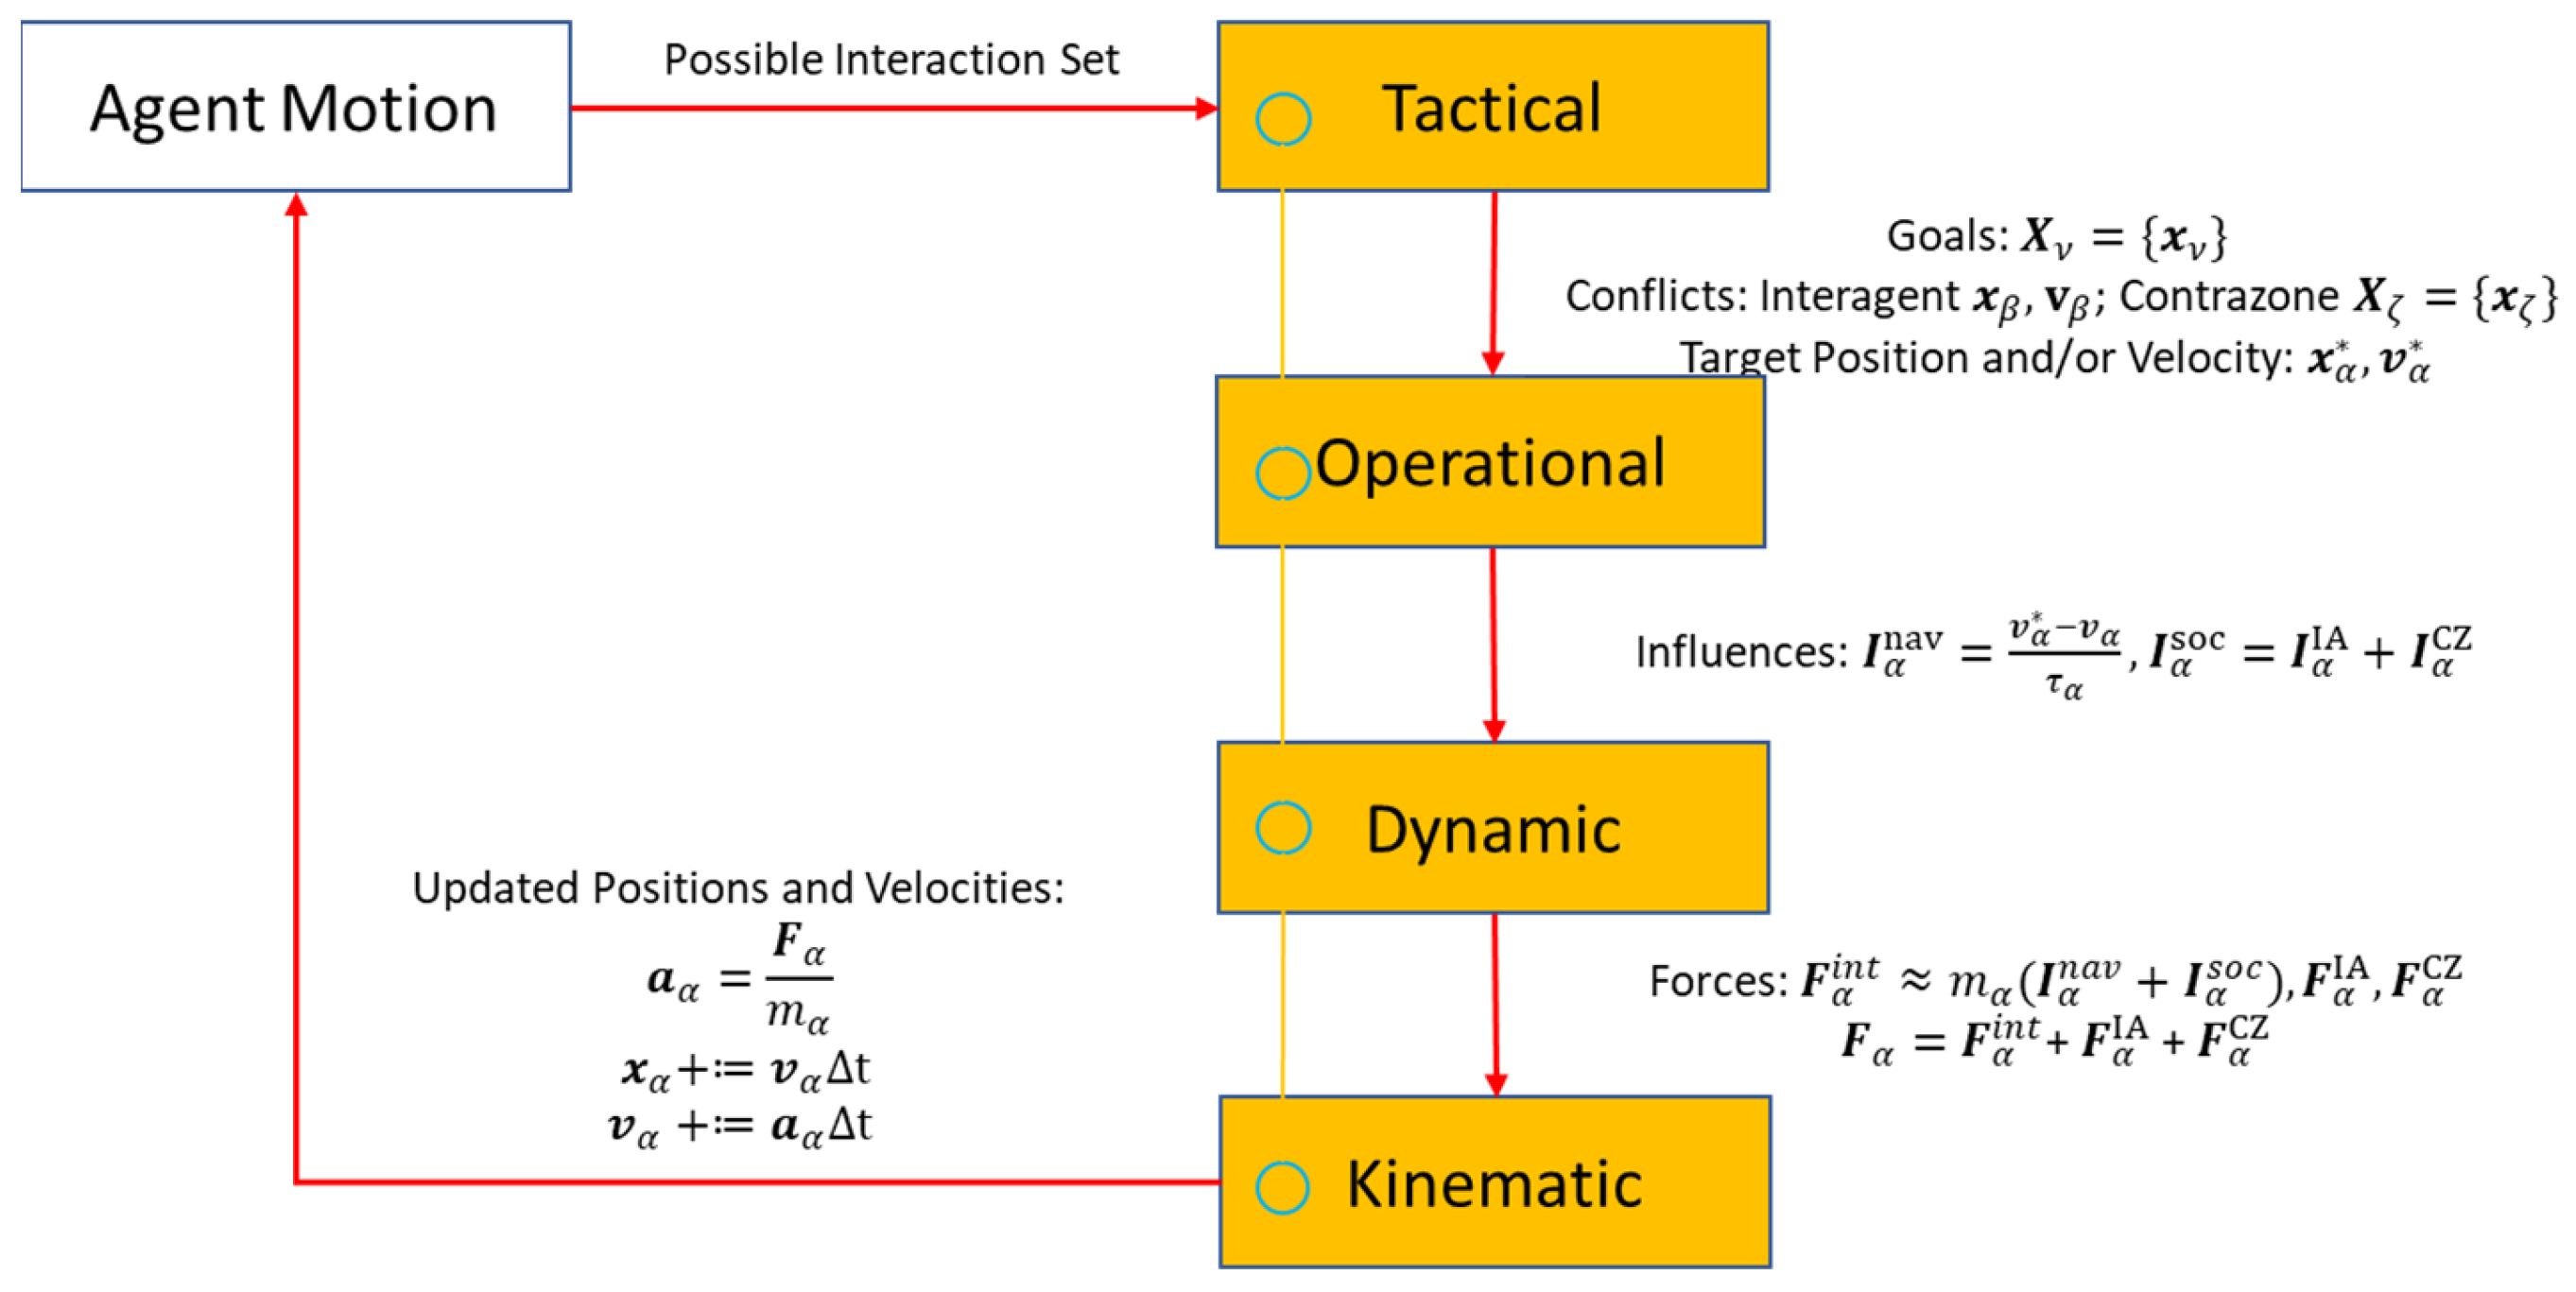
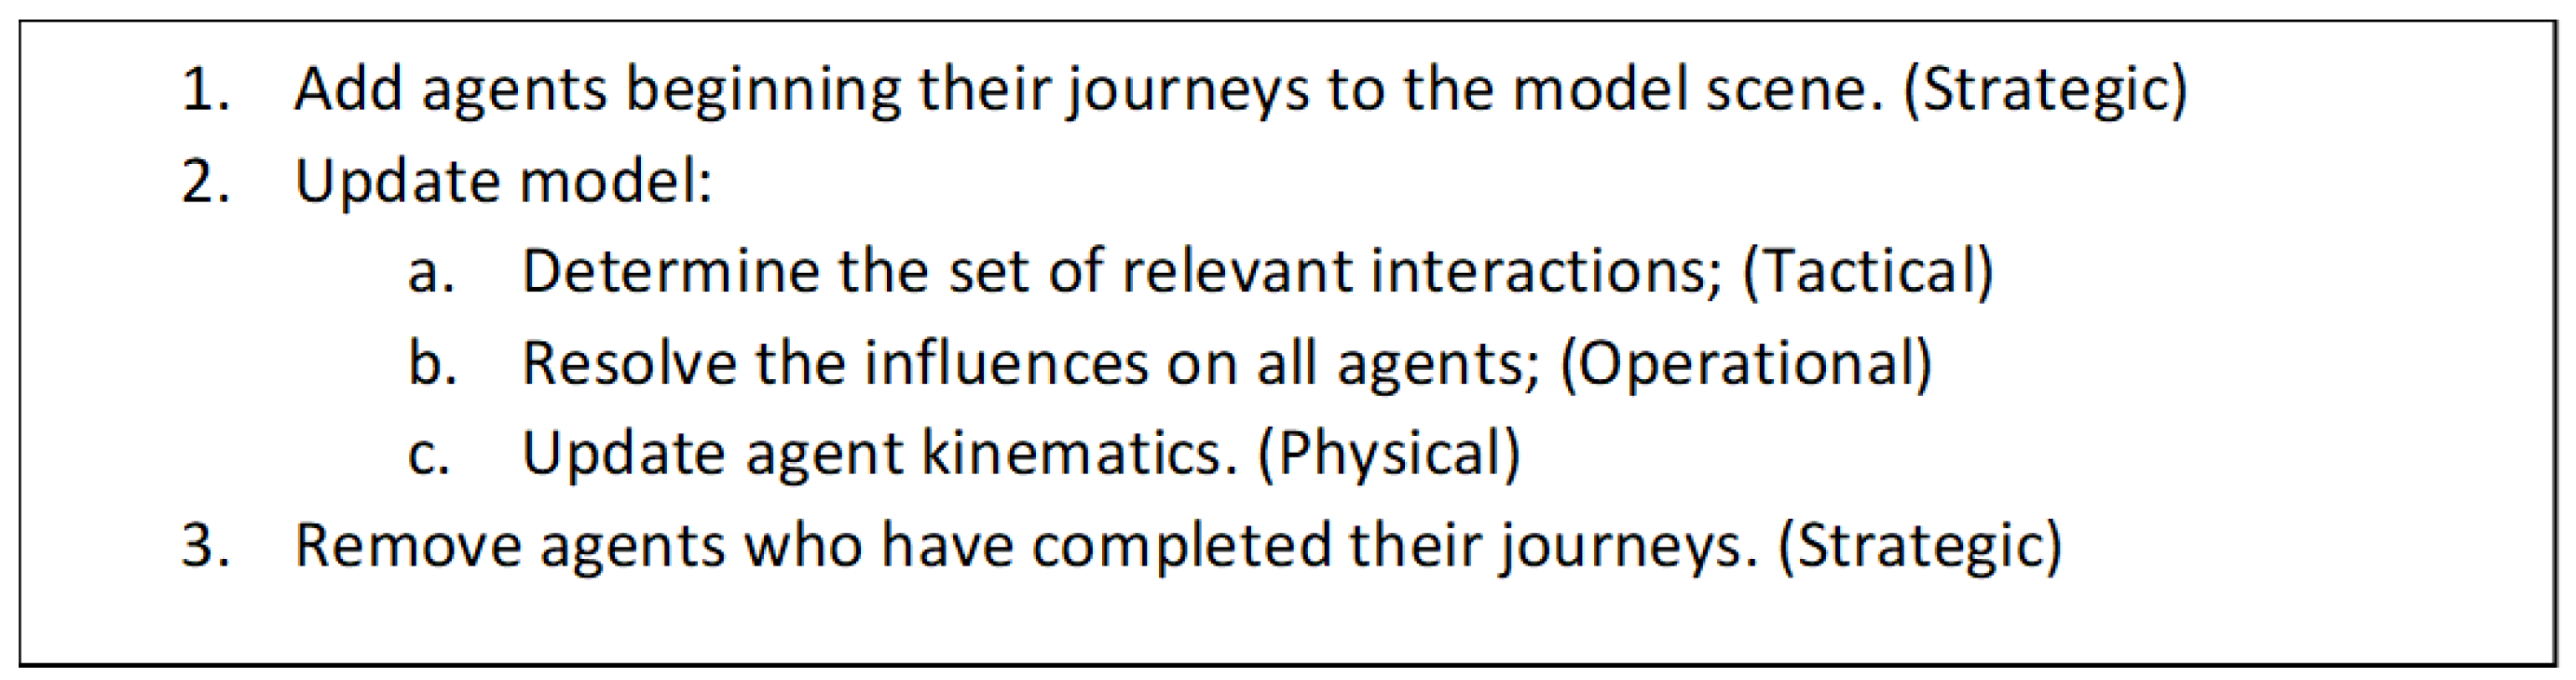
The following paper builds upon the research presented in Slack-Smith et al. [11] by specifically detailing the advancement of the social force model to better incorporate realistic interactions of multiple agents in multiple modes. The next section details the related background literature to define the current state of modeling from a foundational perspective. Leveraging the state-of-the-art, the paper then describes the development of a novel modeling framework called the Integrated Pedestrian–Vehicle Model (IPVM) that supports multiple transport modes within a multimodal social force model which also integrates the velocity obstacle approach [12,13,14,15] for proactive interaction handling. Thus, the IPVM has the potential to advance and operationalize shared space modeling.
2. Literature Review
Slack-Smith et al. [11] present a detailed categorization of the shared space modeling literature to date and describe relationships between some of the main literature relevant to shared spaces, including pedestrian models, vehicle models, and shared space models. Categorization shows that traffic modeling can be separated into macroscopic (leveraging aggregate representations, e.g., [16]) and microscopic (depiction of individual agents, e.g., [8,10]) modeling.
The most well-known physical model used for microscopic modeling of pedestrians is the social force model (SFM) [9,17,18], which has previously been adapted to depict inter-vehicular interactions [19] and short-range intermodal interactions such as pedestrian–vehicle interactions [8,10]. Subsequent work has extended the SFM to consider longer range (timescale) collision avoidance through the application of game theory [8,20], cost-minimization [21,22], curve-fitting [23], and discrete choice models [24,25]. While the SFM supports multiple conflicts well at short ranges/timescales through linear superposition [9], multiple conflicts at longer ranges/timescales have not been investigated in sufficient detail and further research is necessary [26,27,28].
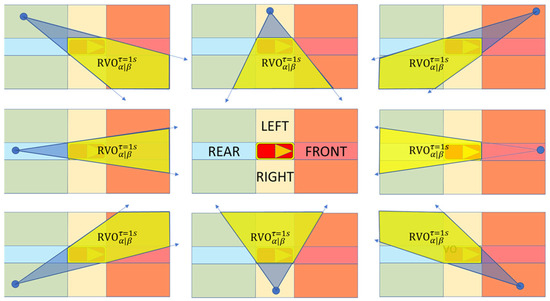
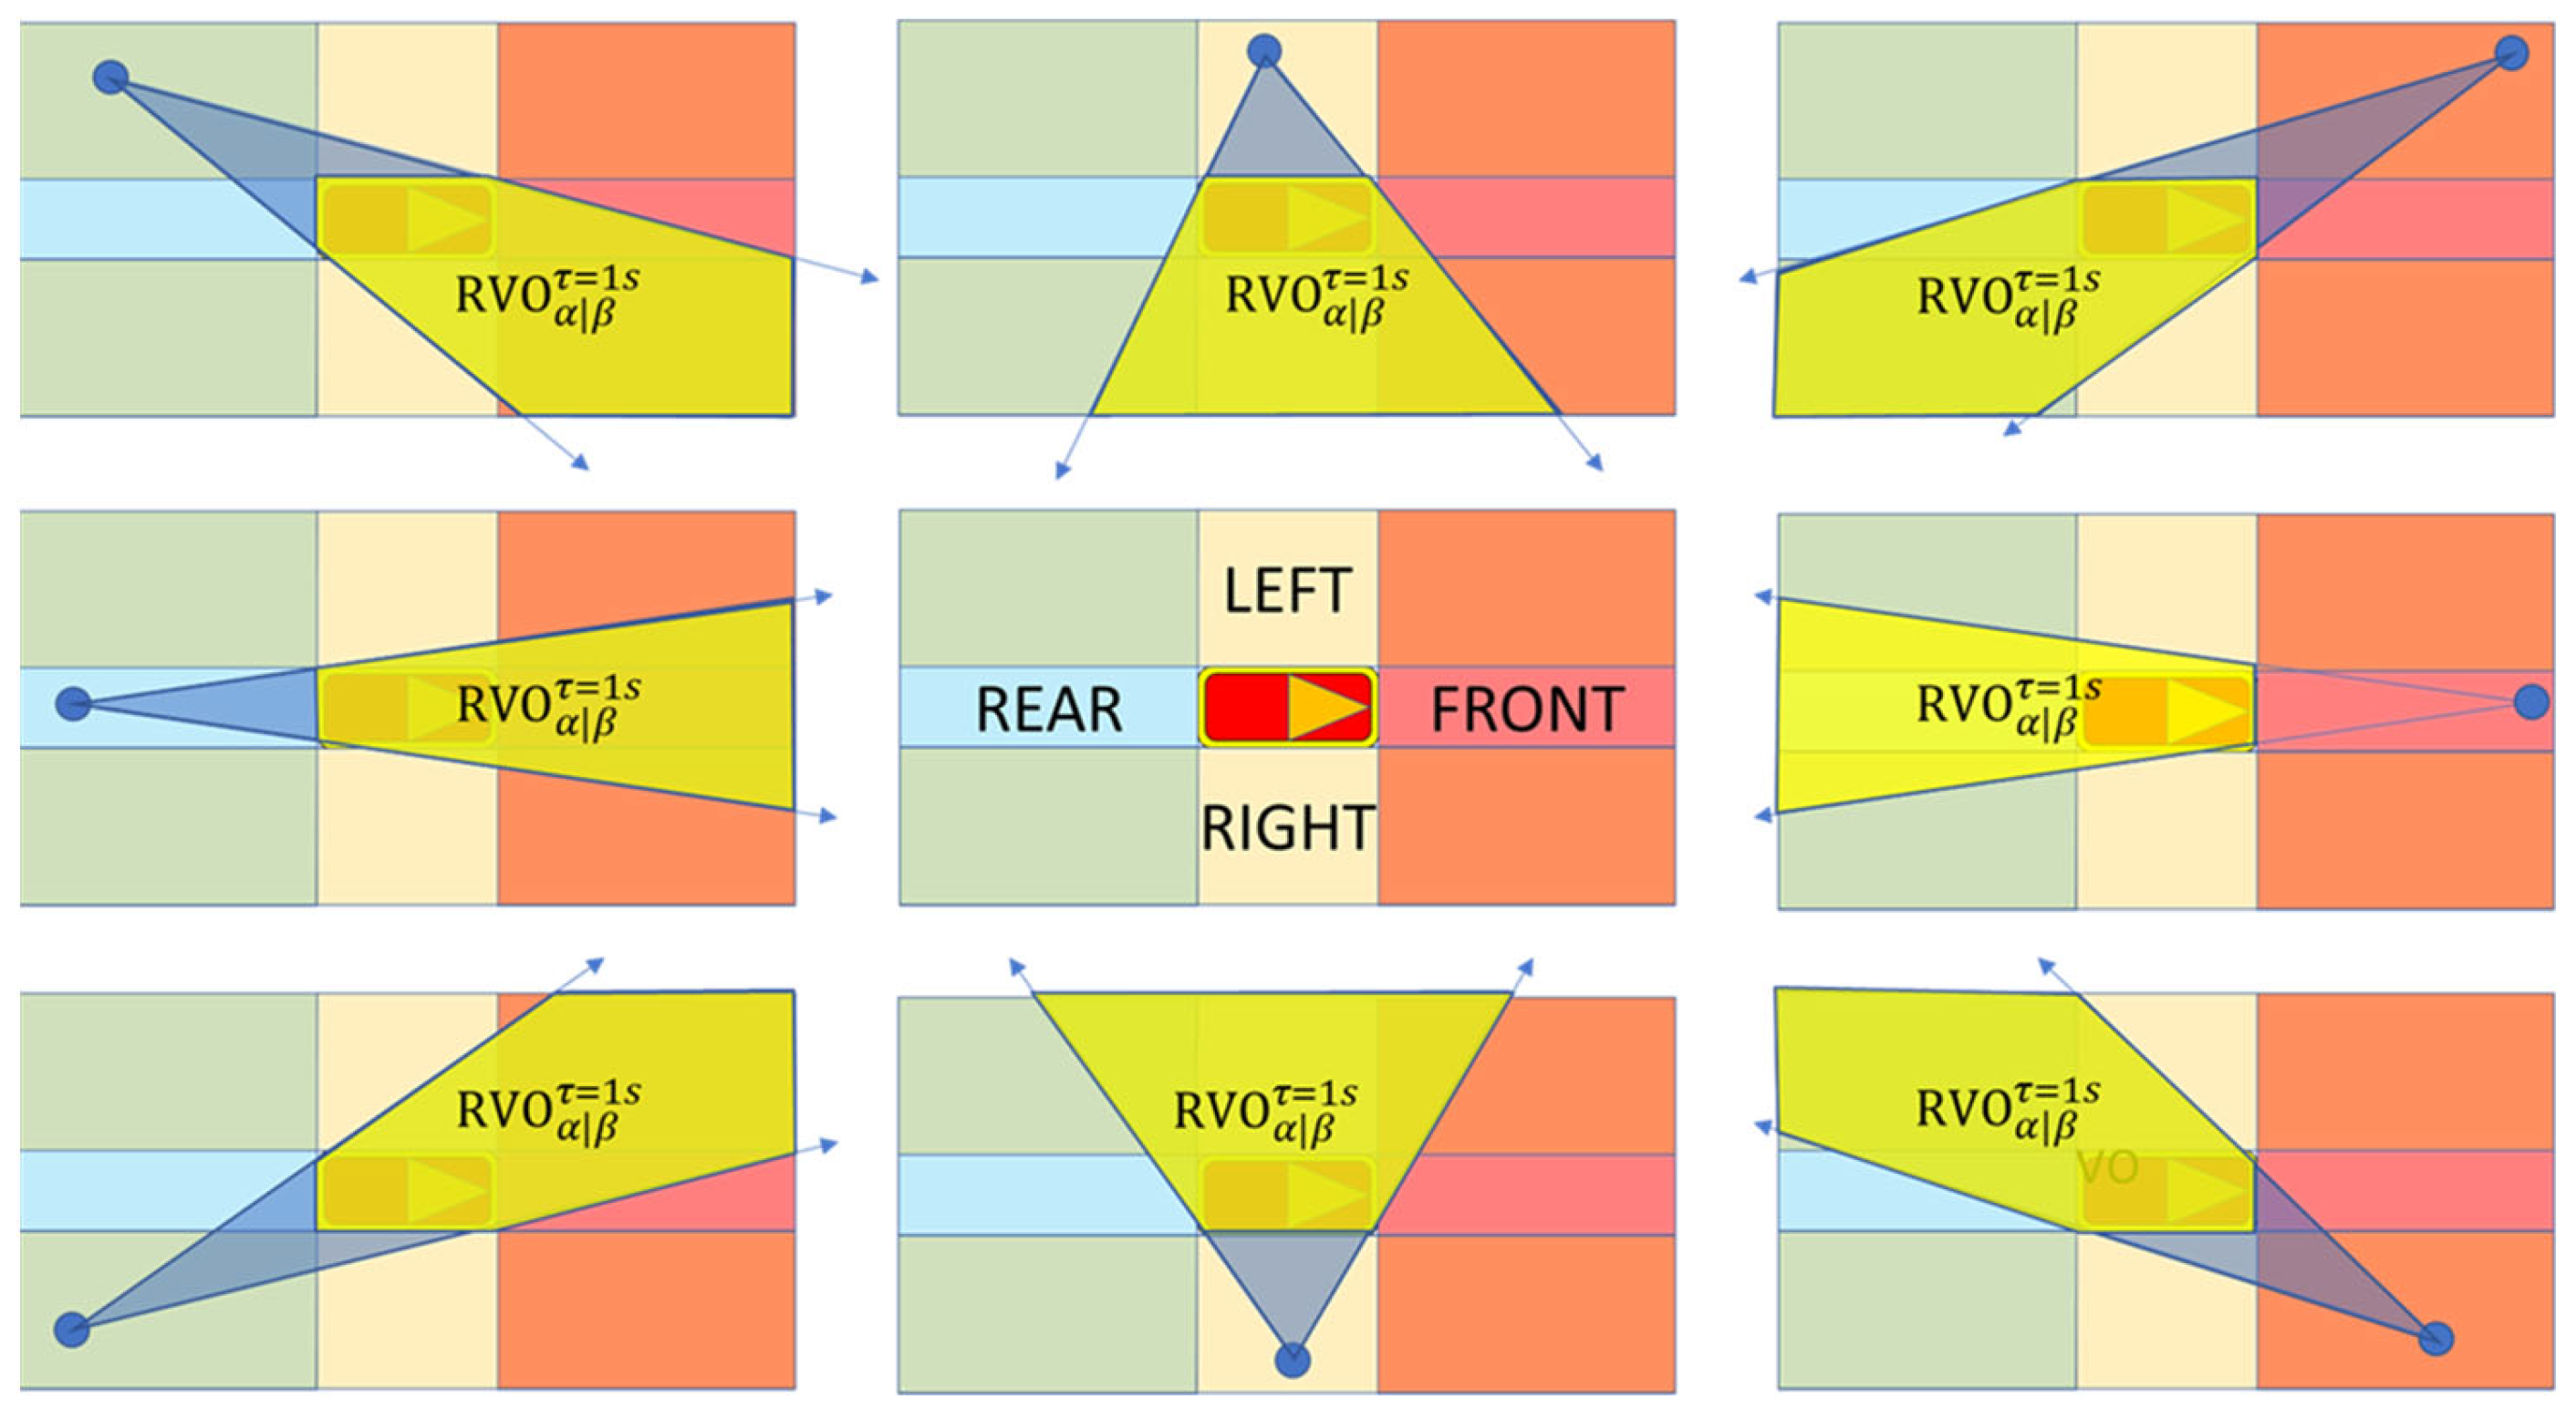
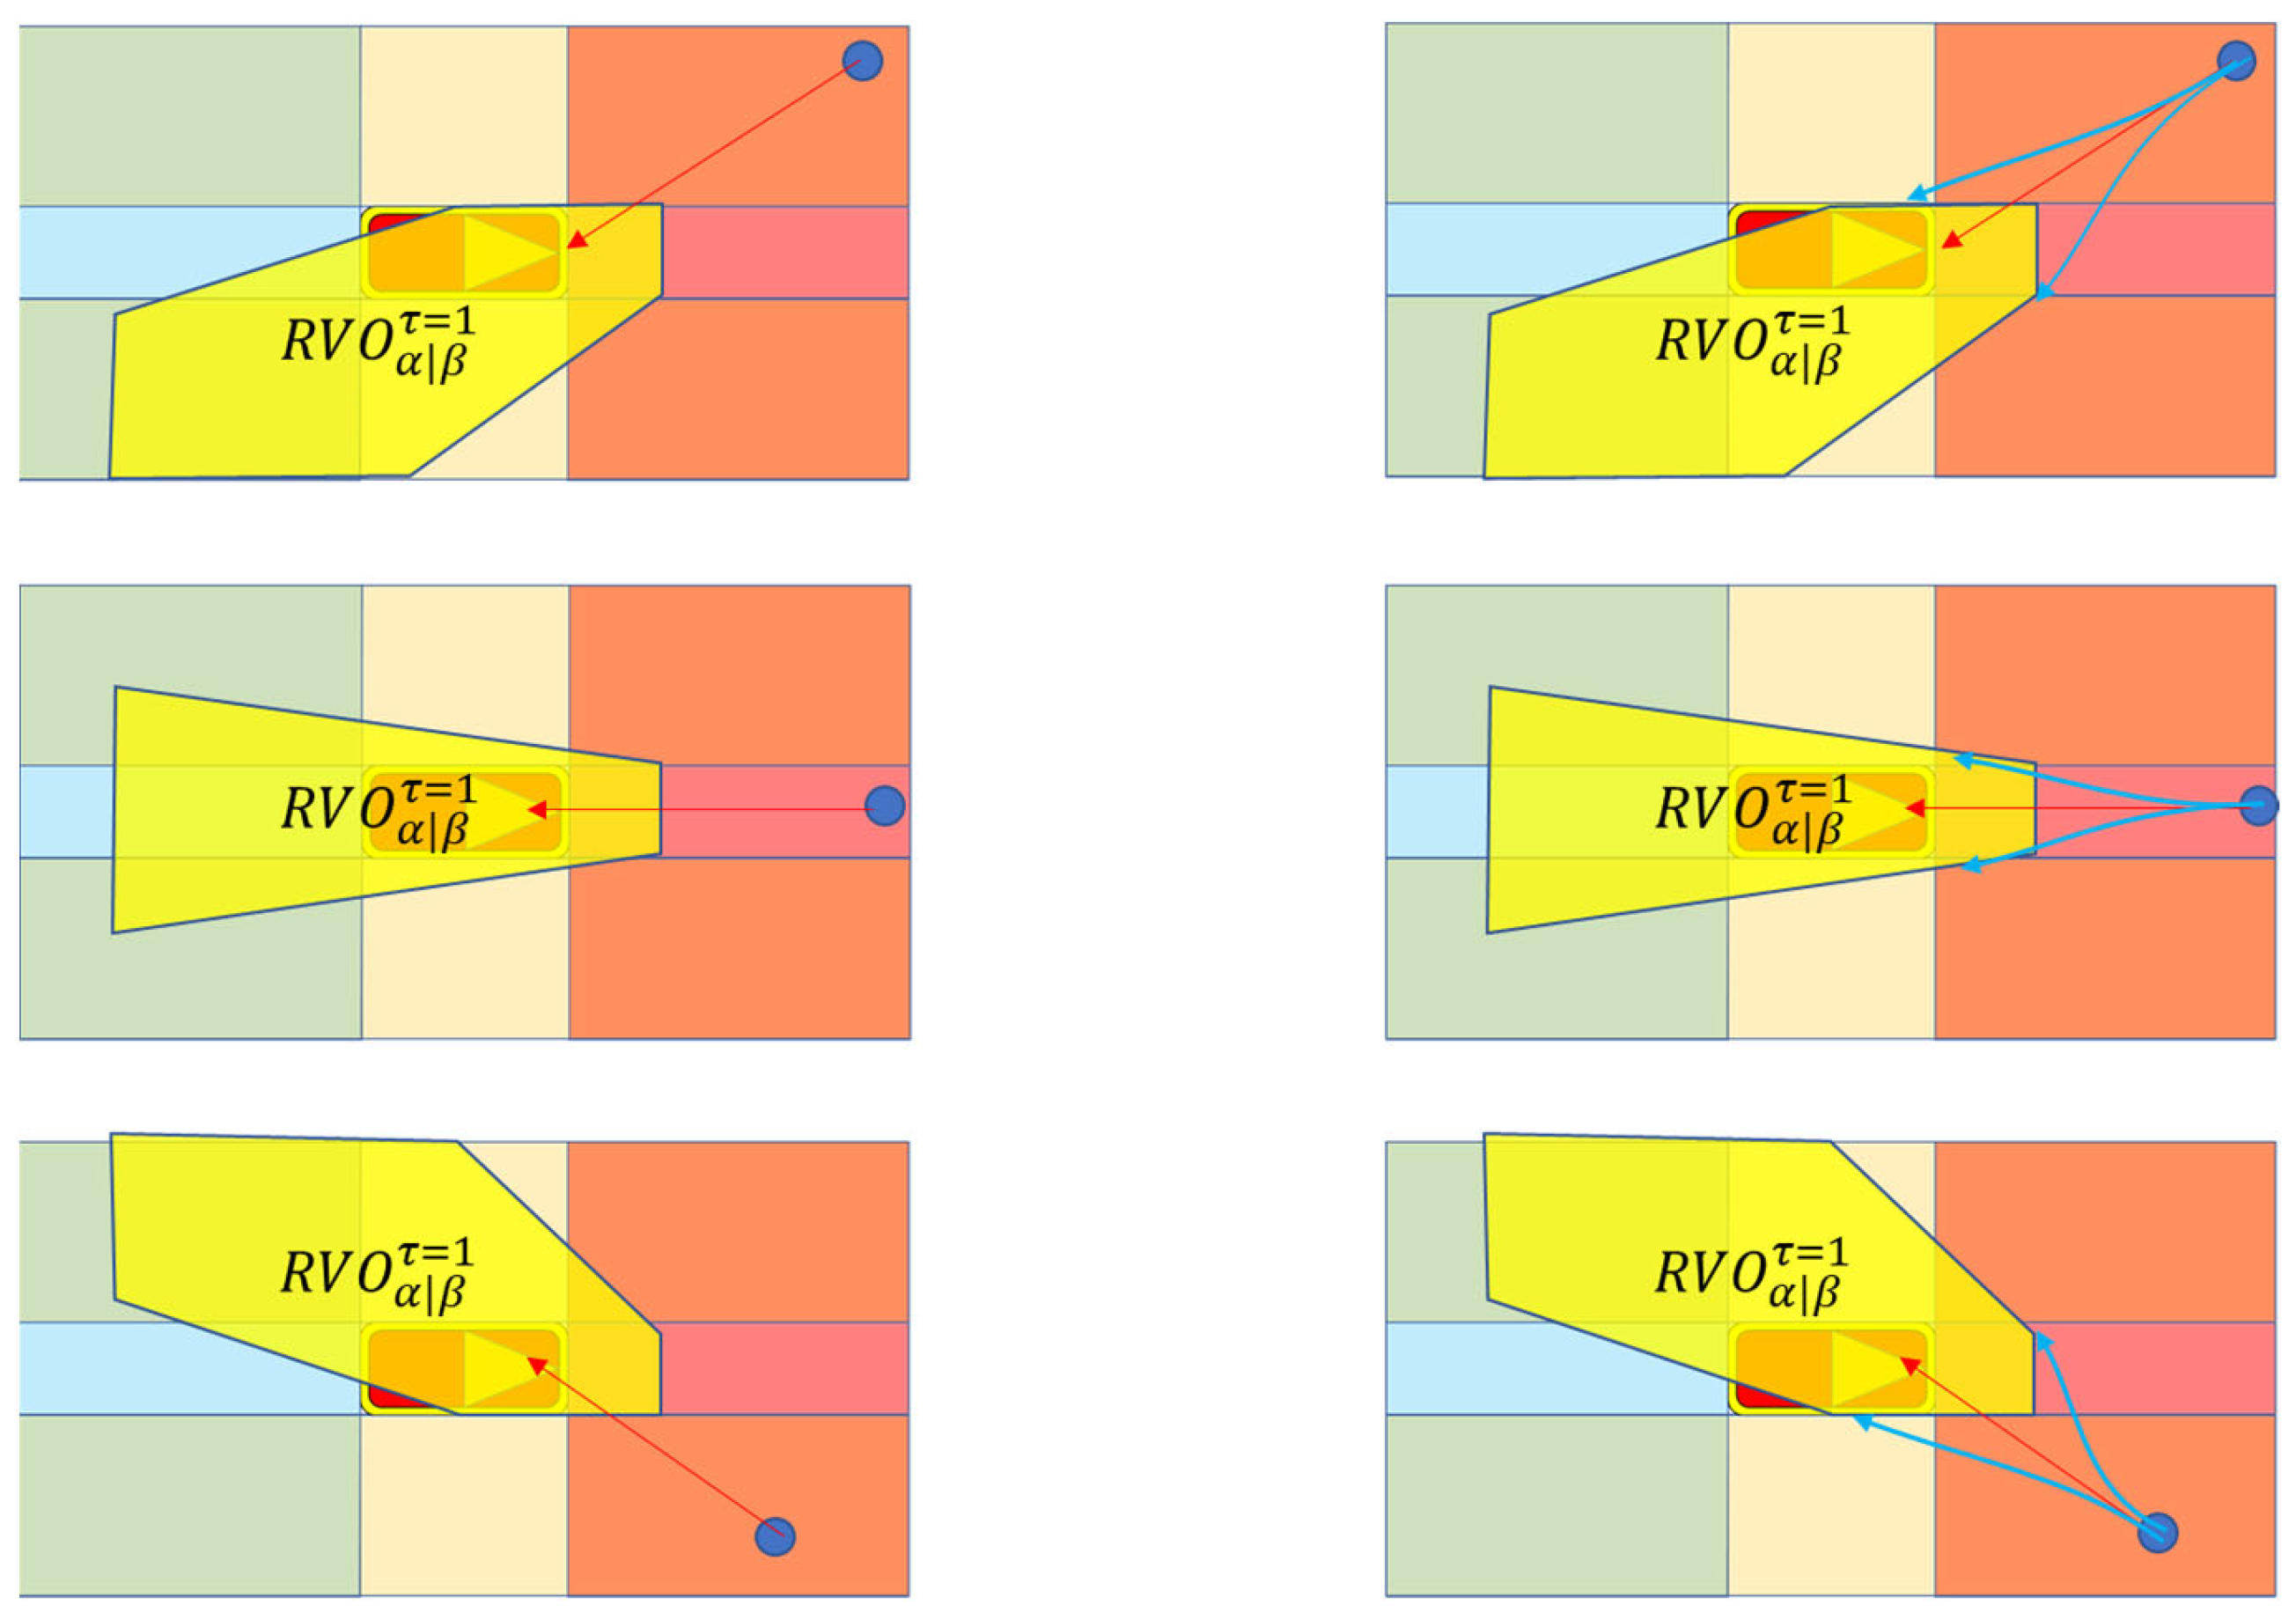
Another research field that can provide insights to future shared space modeling is the mobility of robots. Robot cooperative motion has made extensive use of motion models based on velocity obstacles [12,13,29]. A velocity obstacle is a concept used in robotics and computer science to help a moving object (a robot or a person), avoid collisions with other moving objects. It represents potential paths that an object can take to avoid collisions, and thus could be leveraged in modeling interactions within shared spaces. Interestingly, this work and the social force model [9,17] were both inspired by Reynolds’ rule-based flocking model [30]. Fiorini and Shiller [12] proposed the velocity obstacle (VO) concept to enable robots to avoid objects moving at a constant velocity as well as static obstacles, but it did not attempt to describe mutual avoidance [29]. van den Berg et al. [13] extended the velocity obstacle concept to the reciprocal velocity obstacle (RVO) by distributing responsibility for avoidance between the agents. If both agents are assumed to be capable of making the same calculations, this yields an effective algorithm for collision avoidance. van den Berg et al. [31] extended the algorithm to handle multiple collisions with the optimal reciprocal collision avoidance (ORCA) method, in which each agent derives a half-plane constraint from each of its counteragents and then constructs a convex (usually polygonal) constraint for the agent’s desired velocity. In addition, the method has been extended to wheeled robots and autonomous vehicles [14,15,32,33] and aerial autonomous vehicles [34,35,36,37,38].
The velocity obstacle approach has also been applied to pedestrians [39,40,41,42,43] and human-driven ground vehicles [44,45]. Previous work has added new features for modeling pedestrians such as virtual agents in the vicinity of pedestrian agents [39] to a velocity obstacle model to represent social phenomena such as priority/privilege arising from aggression, authority, and guidance; right-of-way to describe pedestrian priority [46]; potential fields for crowd simulation [41]; multiple timescales to support long-range collision avoidance [42]; and average group velocity to support grouping [47]. Other work has integrated motion constraints to support wheeled robots and vehicles such as a steering model [32], acceleration–velocity obstacles [14], and (smooth) control obstacles [15]. Finally, other research has explored the use of more varied shapes based upon the medial axis transform (skeletonization) to allow diverse mixed traffic to be supported [44,45].
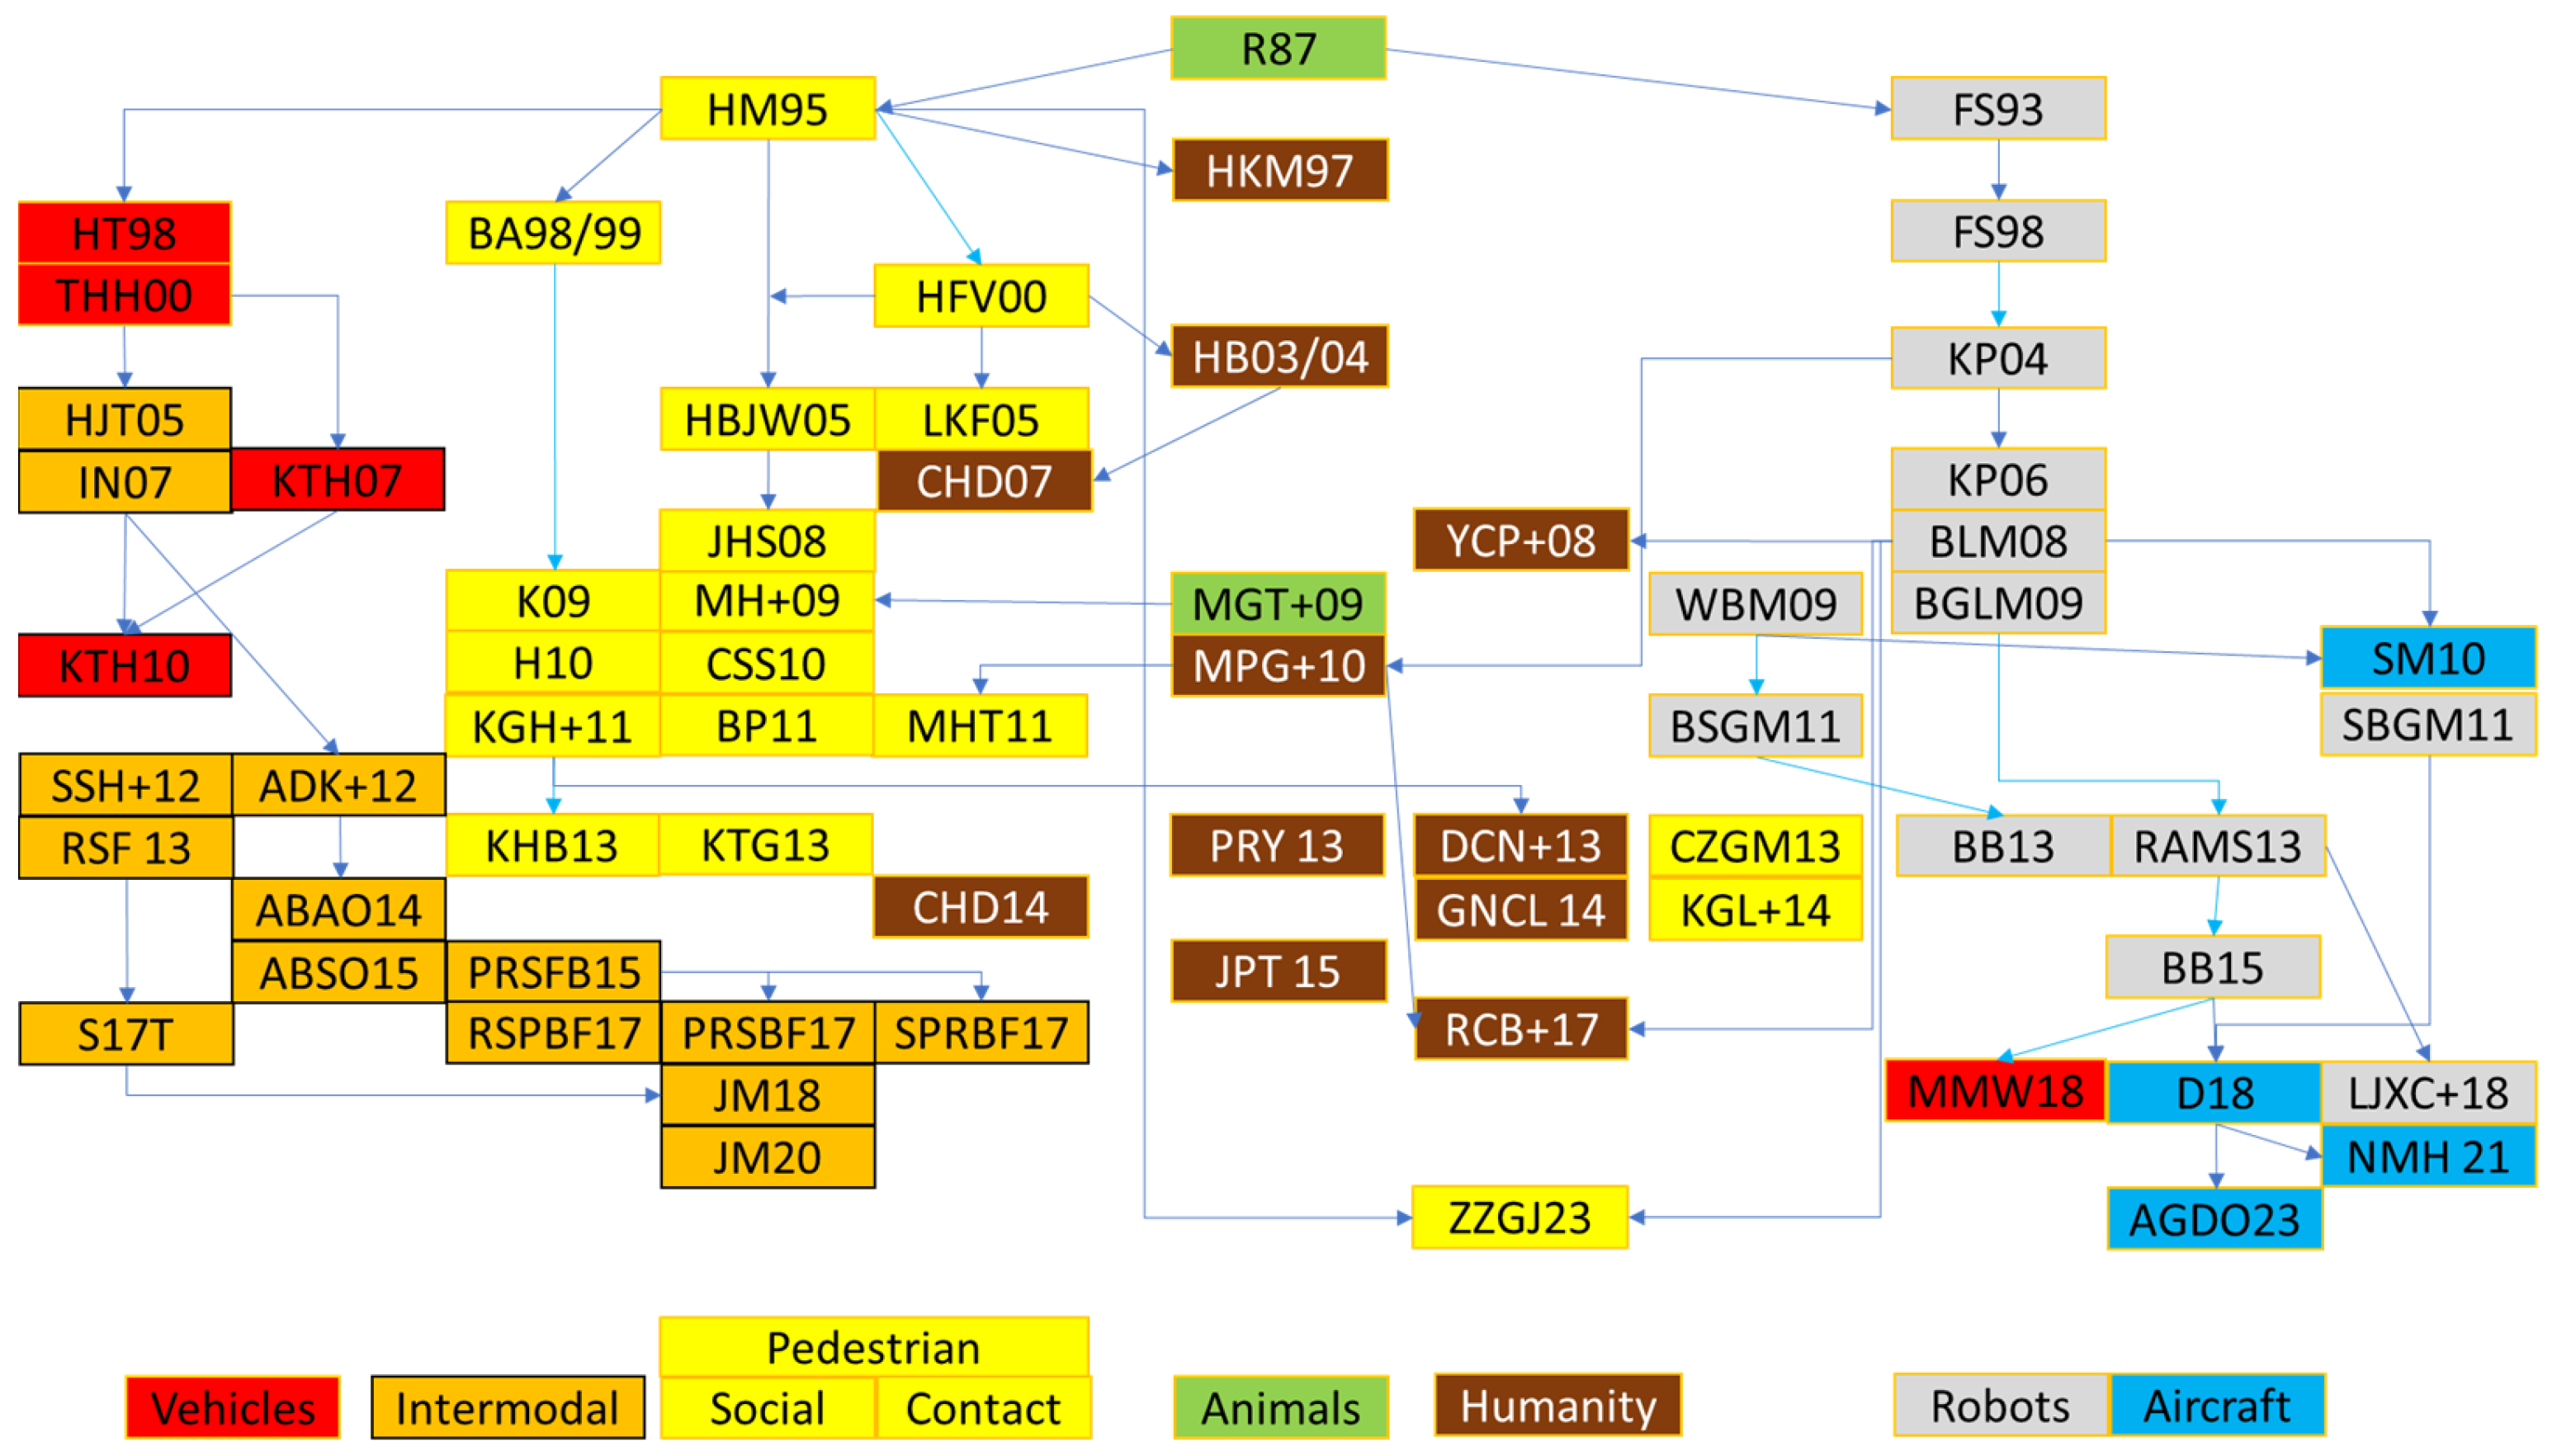
Figure 1 depicts the relationships between the literature identified in the review. The color coding of the rectangles represents the different fields that have investigated the modeling of shared spaces. Red represents models that are focused on vehicular movements. Orange represents models that describe interactions between vehicles and pedestrians. Yellow represents pedestrian movement and interaction models. Green represents animal behavior models, for example, models that mathematically define flocking, herding, and schooling. Brown represents “Activity Oriented Modelling” that focuses on more than just the movement of users from origin to destination but also takes into consideration activities and social interaction. Grey represents robotics models and blue represents aircraft movement models. The text coding presented within the smaller boxes of Figure 1 refers to the initials of the authors and the year of publication of each key paper, for example, “HT 98” refers to the paper published in 1998 by Helbing and Tilch [19], “HJT 05” refers to the paper published in 2005 by Helbing, Jiang and Treiber [48] and so on and so forth. Appendix A provides an exhaustive list of the coding presented in Figure 1. The arrows between boxes present the interconnected nature of the evolution of the literature concerning the modeling of shared spaces. An example of this is Zhang et al. (ZZGJ 23) who utilize the SFM from Helbing and Molnár (HM 95) as well as the RVO from van den Berg et al. (BLM 08) [9,13,49].
Figure 1.
Connectivity of relevant modelling literature (q.v. Table A1 for detailed explanation, the figure is coded to represent initials of authors followed by year of publication).
Leveraging the categorization of the literature provides insights into how robotics has shaped recent efforts in traffic modeling with the advantage that multiple conflict situations can be handled simply and efficiently [31], but the disadvantage of relying upon each agent being able to make the same calculations independently. Since humans do not calculate as quickly as robots, these methods are likely to be less applicable than the SFM to human interactions on shorter timescales. This leads to questions around the feasibility of amalgamating an SFM with a VO model for the purpose of modeling shared spaces. SFM and VO methods have been directly compared in the context of right-of-way [46]. An asymmetric SFM and an RVO algorithm (ORCA) have recently been combined to model unidirectional pedestrian flow [49].
In addition to the papers focused directly on pedestrians and vehicle traffic, several of the other velocity obstacle papers disclose techniques that could be useful for modeling shared spaces. Though modeling aircraft [34,36,37,38] may not be directly relevant, there are opportunities to use speed management and evasion methods to improve shared space modeling. Pathways could involve tailoring VO/RVO methods to better support vehicles with slow deceleration profiles by assuming constant speed during evasive maneuvers [36]; foreclosing an evasion direction [37]; or expecting non-reciprocal evasive maneuvers when time allows [38]. These could all be applicable to conflicts between pedestrians and vehicles in shared spaces.
The primary focus is on understanding the process of integrating these modeling frameworks. There is also a gap concerning the potential amalgamation of this framework with activity modeling to comprehensively address both the ‘movement’ and ‘place’ objectives within a shared space.
To address the gaps highlighted above, the next section of the paper describes an Integrated Pedestrian–Vehicle Model (IPVM) that will allow us to predict the performance of shared space designs before implementation. Extending the work of Slack-Smith et al. [11], it also details the theory underpinning it and the software design required to implement it. Finally, it integrates the pedestrian modeling equations proposed in [50] to model signalized crossings and attractions (activity areas). While activity models have been integrated into pedestrian models before [51,52], specific integrations to support shared space modeling have not been developed in the current literature.
4. Discussion
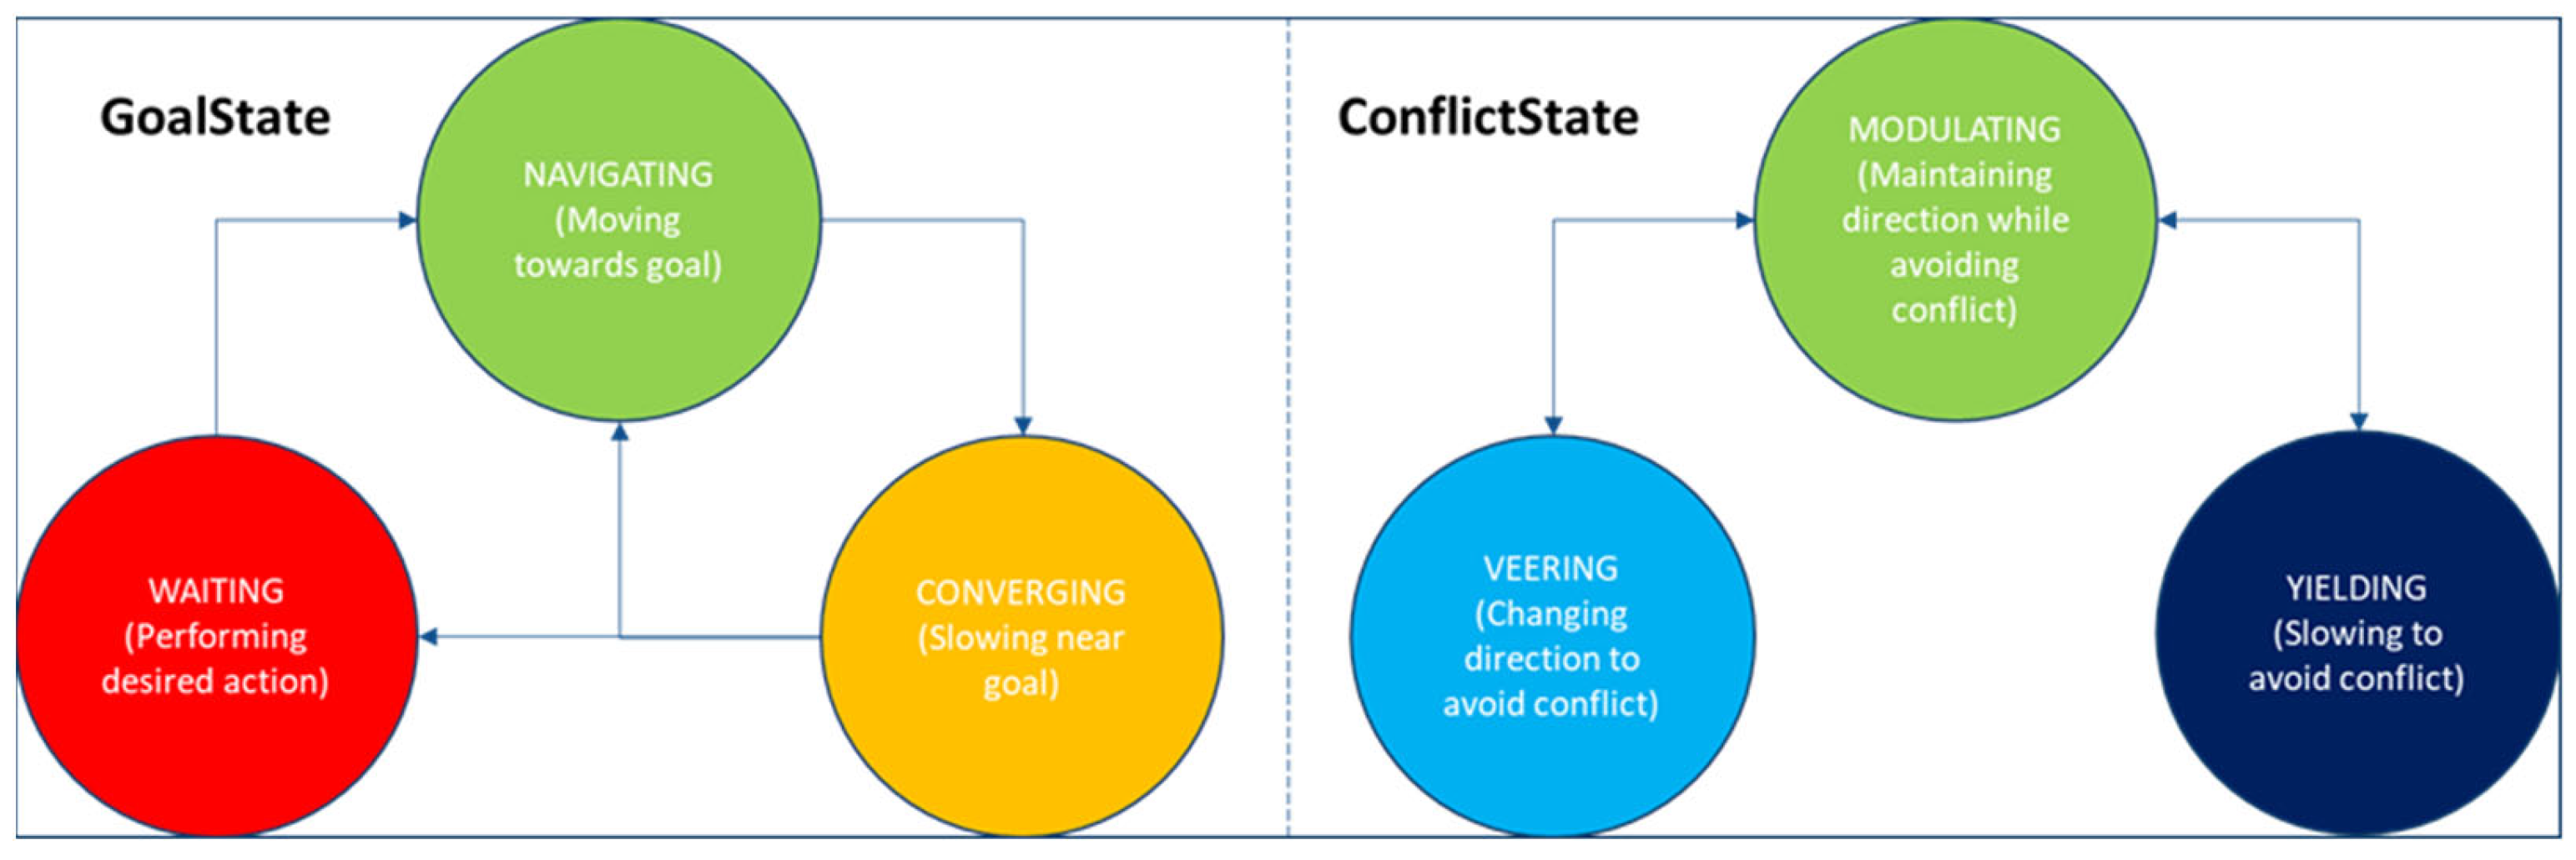
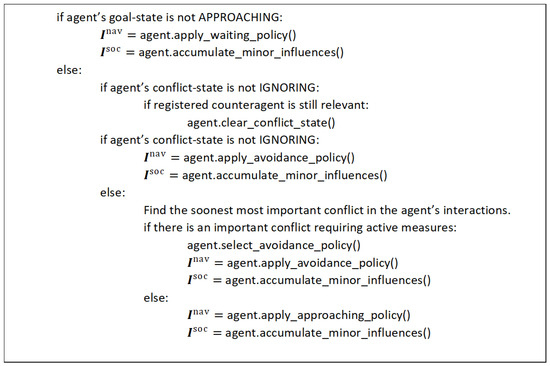
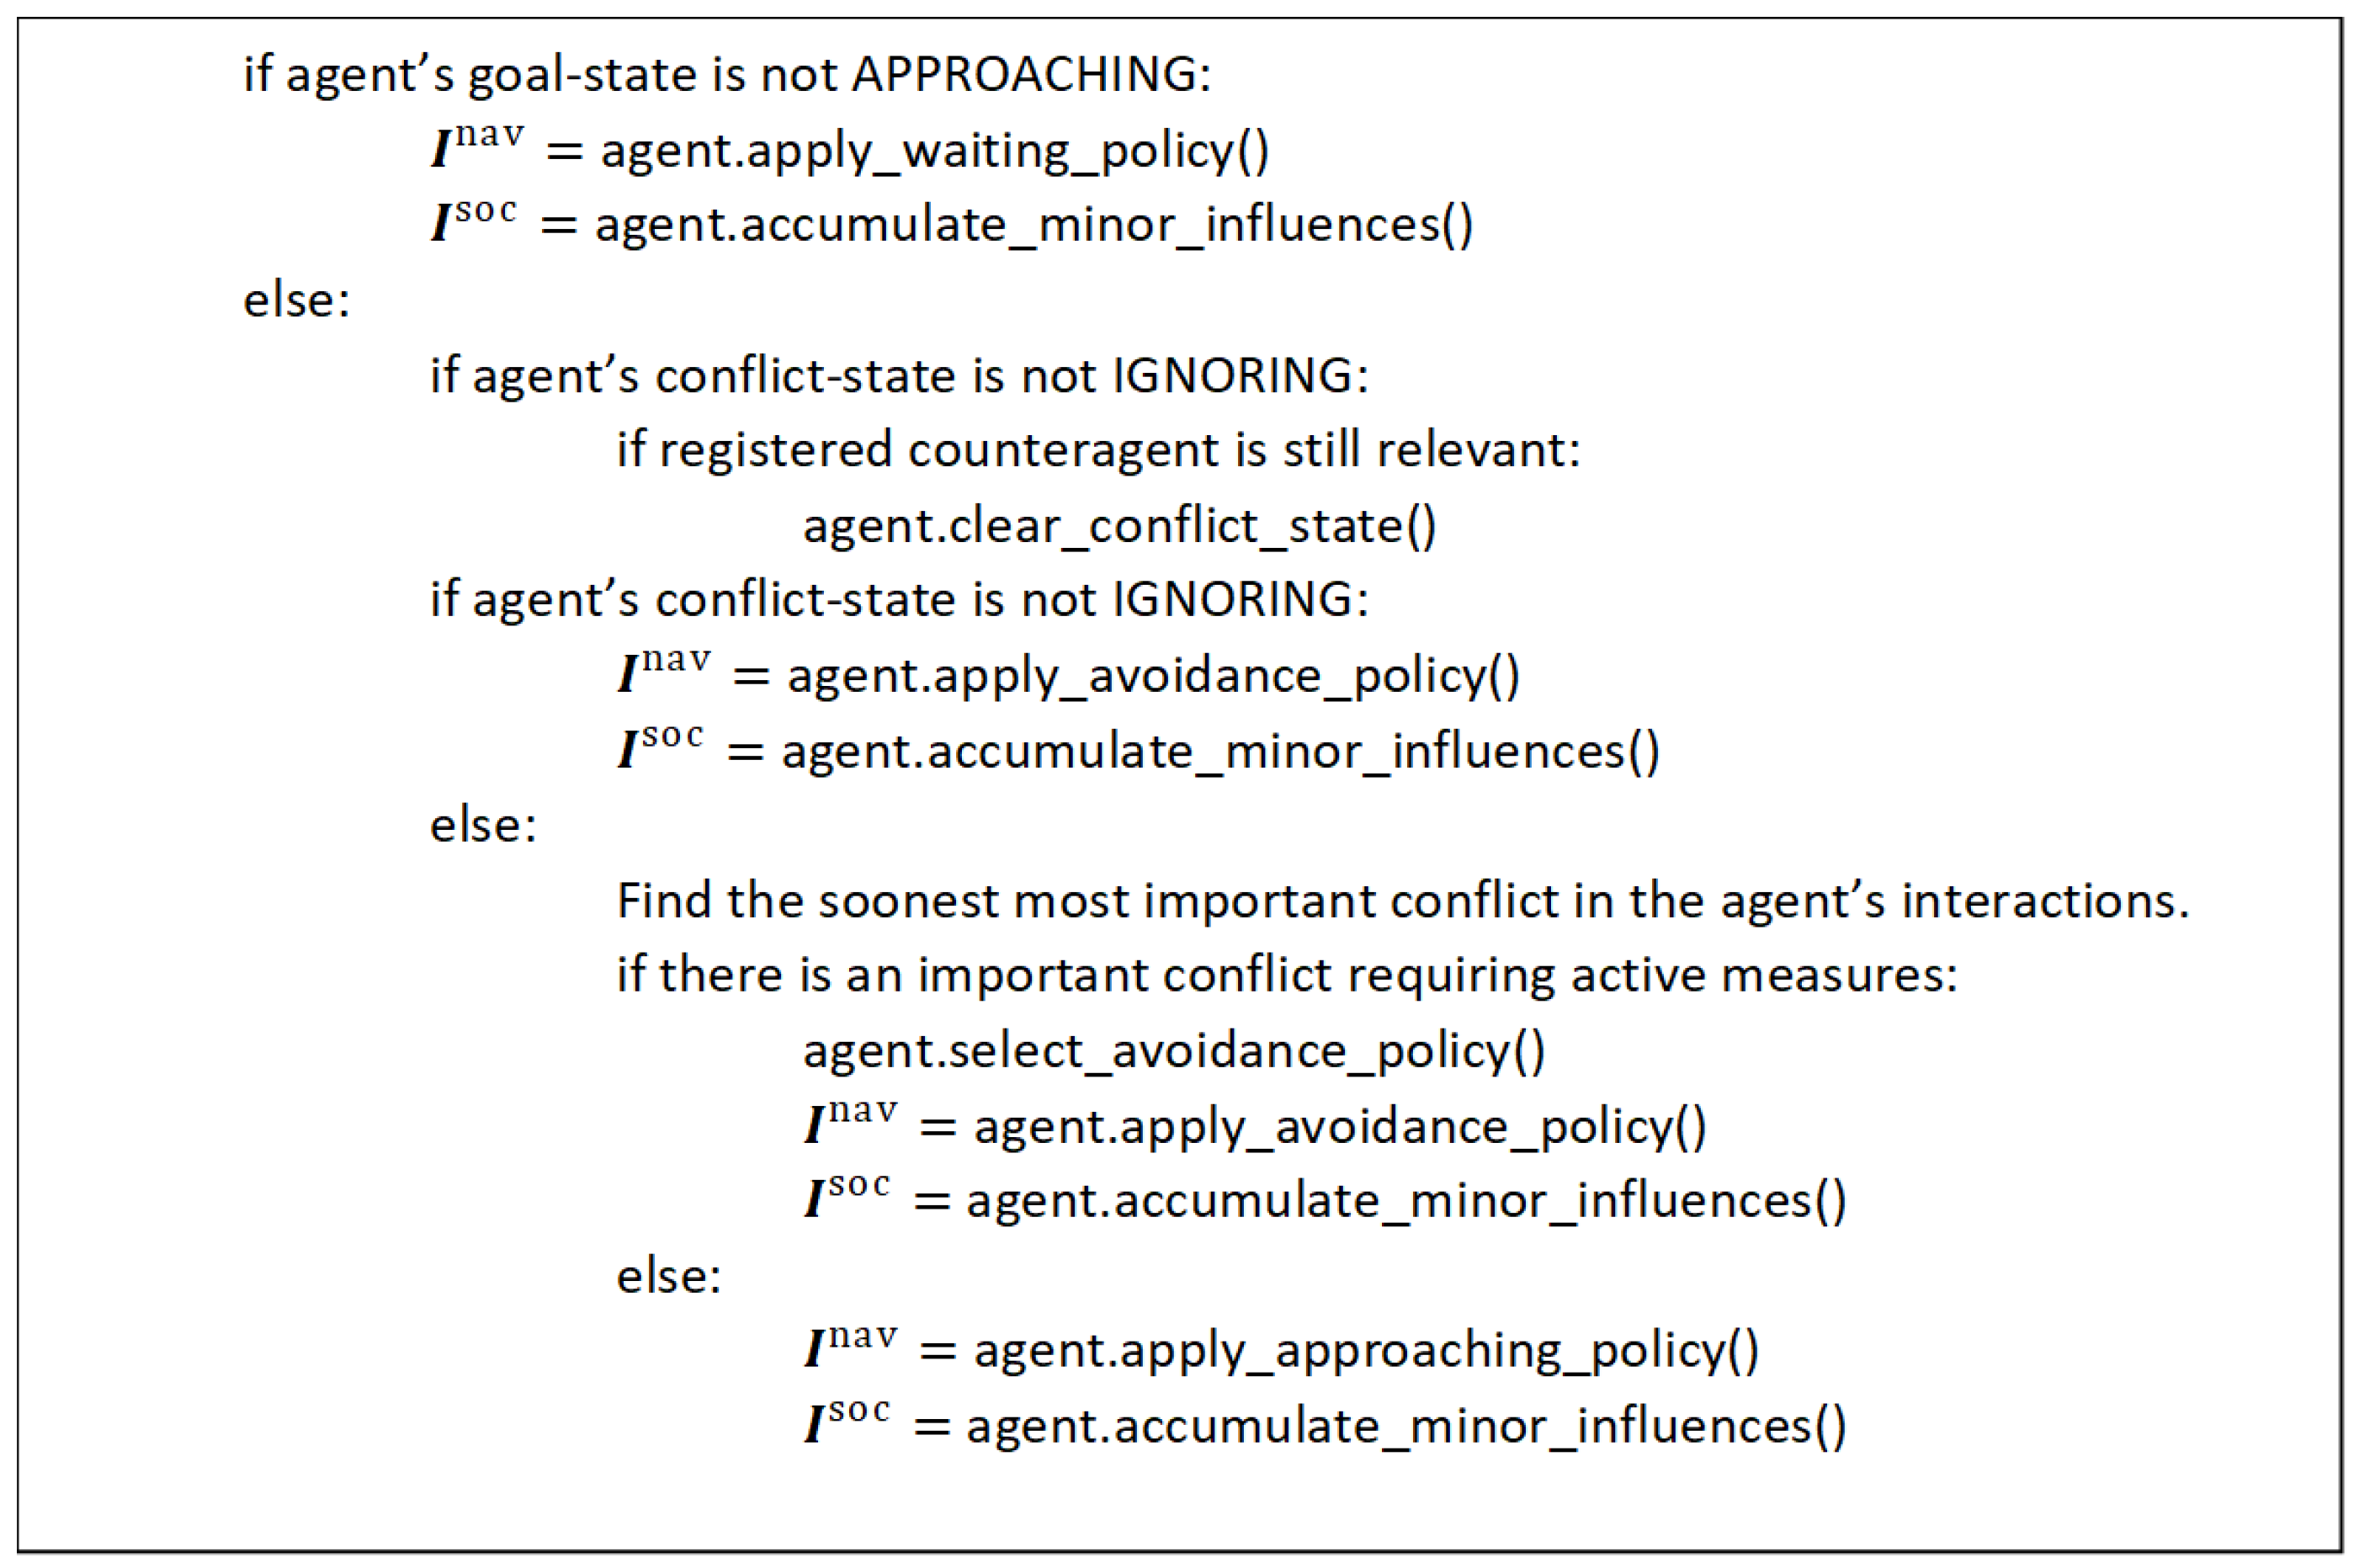
The IPVM presented in this paper has been developed in response to the increasing importance of shared road infrastructure to help communities meet their sustainability aspirations, as expressed in programs such as the United Nations Sustainable Development Goals 9 and 11 [66]. The IPVM is an augmented social force model that enables the evaluation of shared space designs by predicting the effects of both new shared spaces and the revitalization of existing shared spaces. Advancing previous microscopic models, the IPVM supports a streamlined interaction classification, reducing the number and increasing the relevance of interactions each user must consider. This enables a diversity of goal states, offering a more realistic representation of human decision making. This is particularly valuable when individuals are simultaneously working towards their goals while avoiding conflicts with other people and vehicles. It addresses scenarios where conflicting objectives cannot be easily resolved simultaneously, which is common when users navigate between areas of interest and wait within those areas. The inclusion of algorithms from the robotics literature has made it possible to better approximate collision avoidance interactions between vehicles and pedestrians.
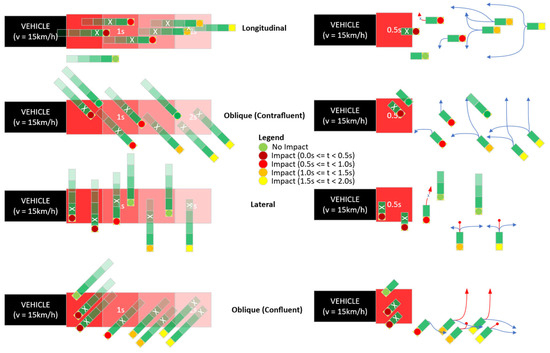
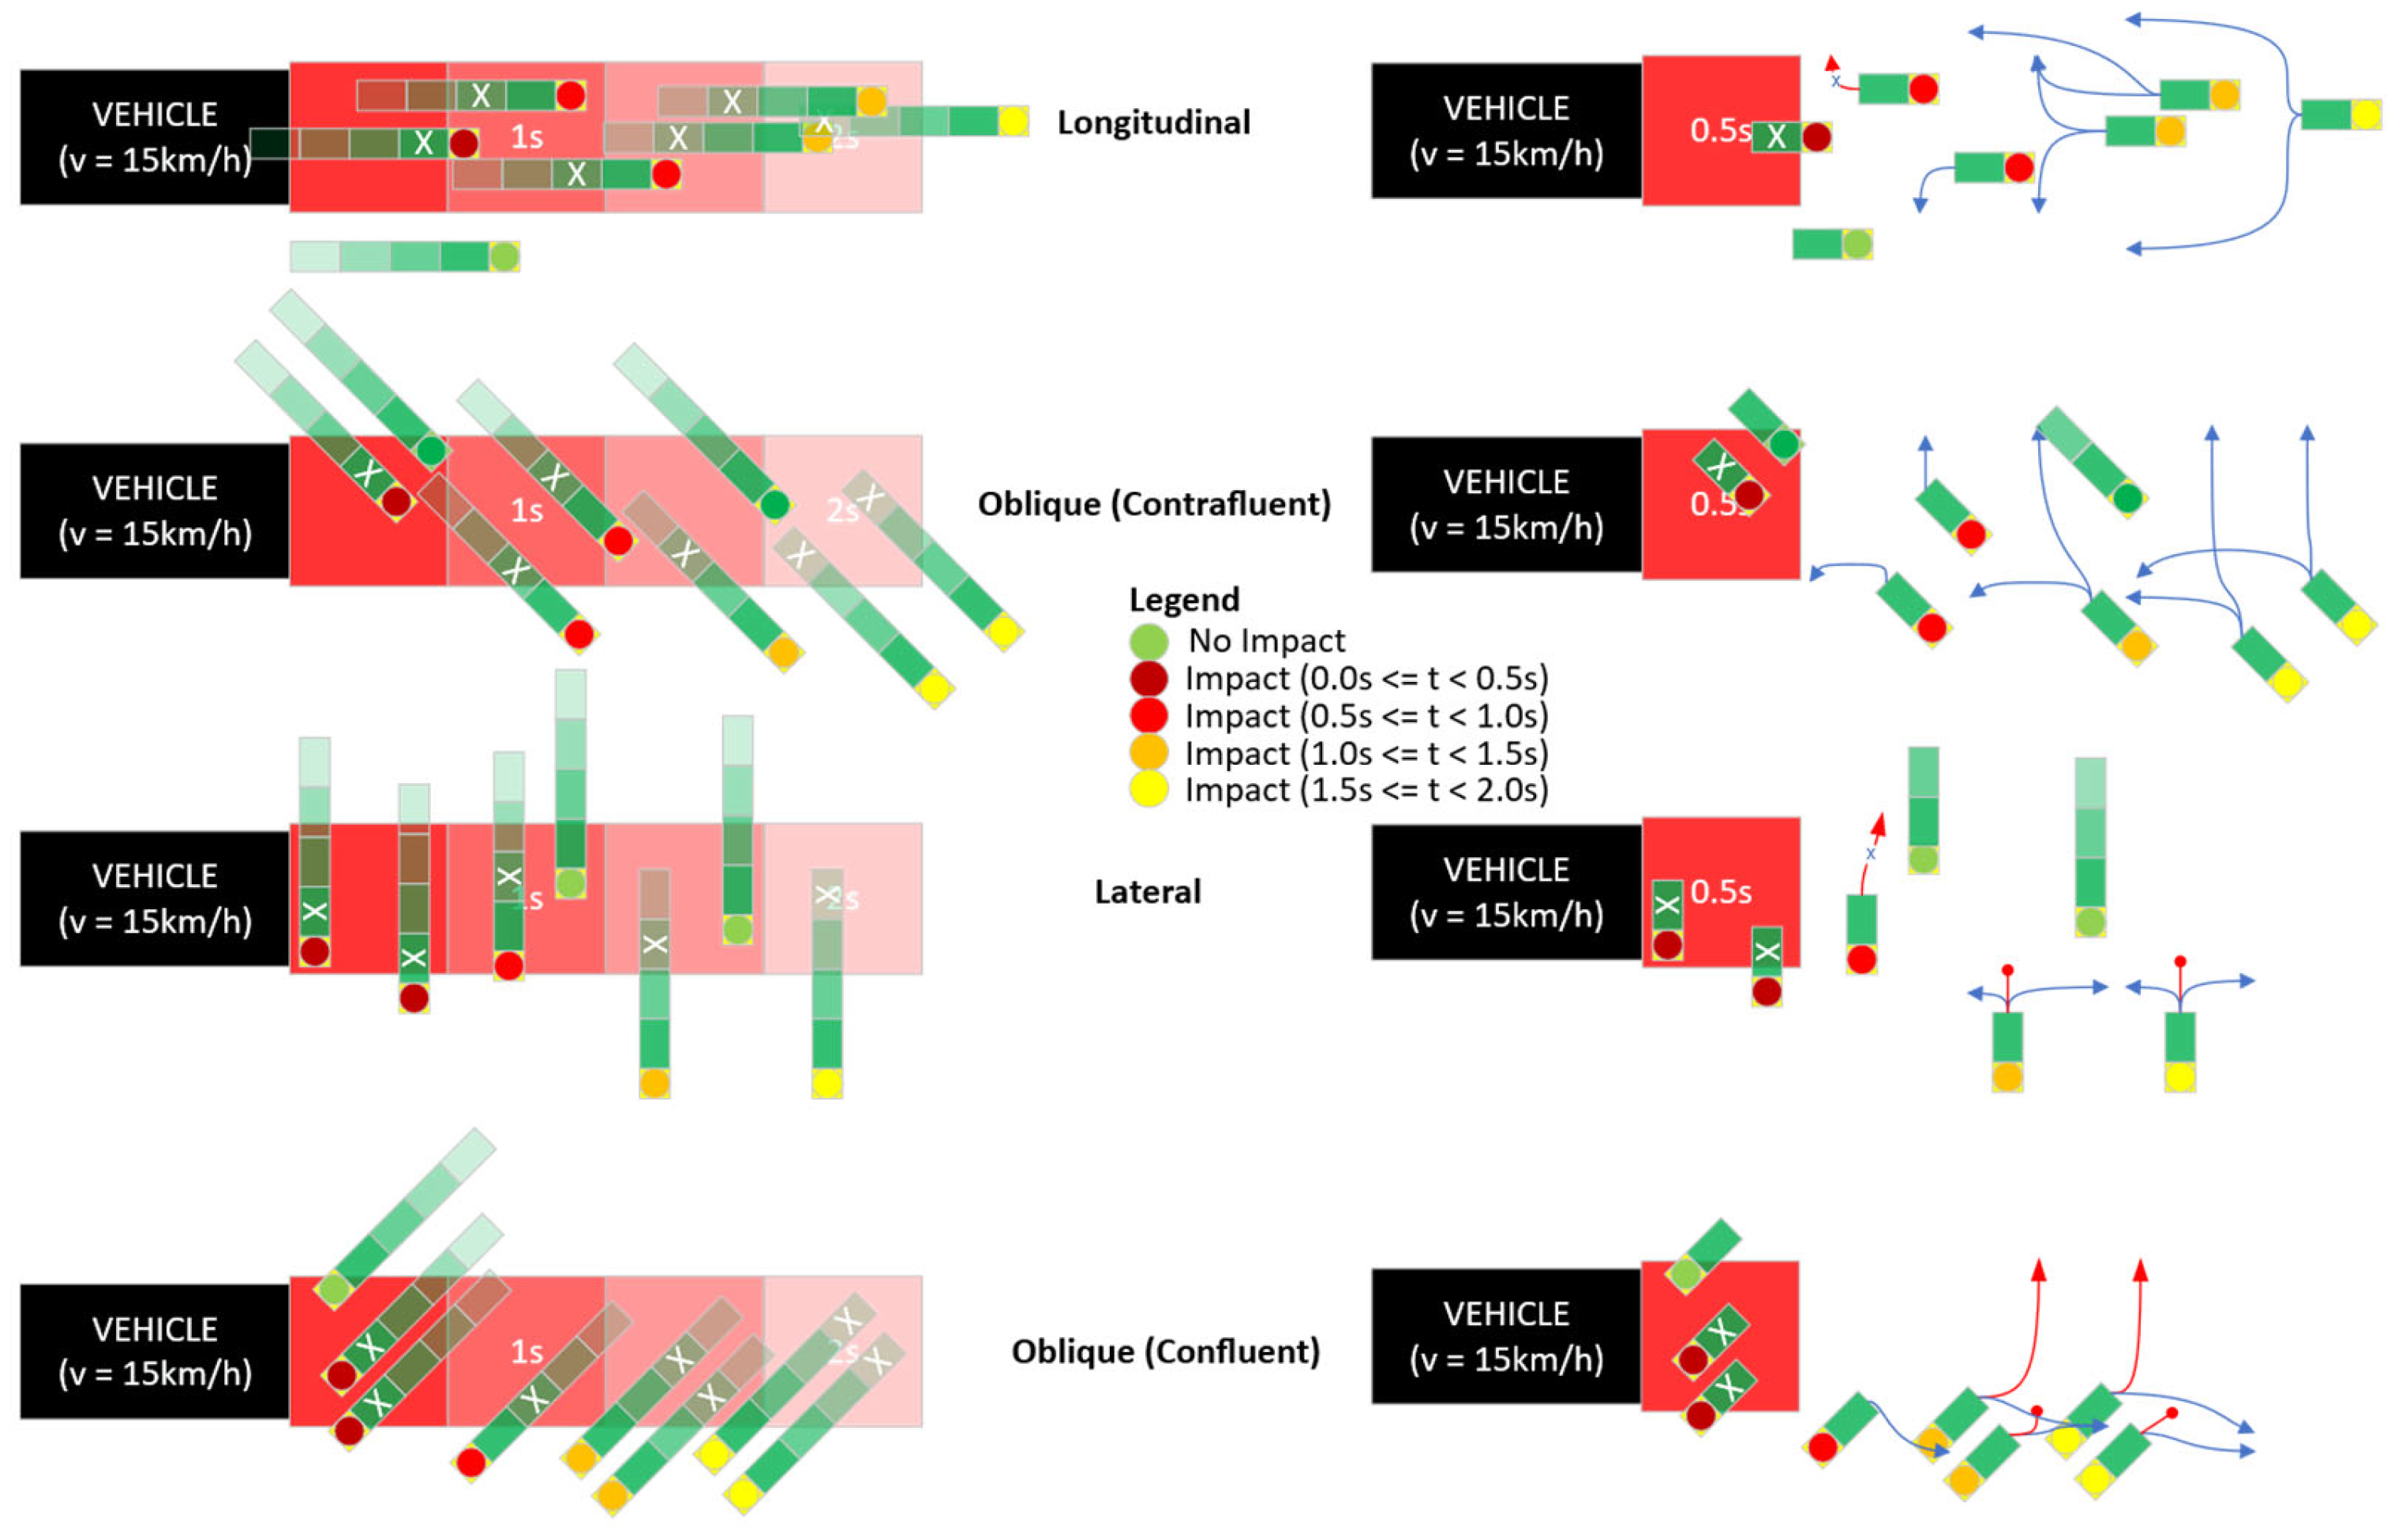
Finally, the model incorporates a more complete conflict taxonomy that provides a detailed categorization of potential deviations pedestrians and vehicles can take to avoid conflicts with other users. This allows for a broader range of user choices, while keeping the computational load manageable by requiring consideration for only a limited number of possible deviations. The advantage of capturing the complexity of the taxonomy of conflicts is important to describe vulnerable users interacting with the road space. Though not currently detailed, the flexibility of the modeling framework would allow for the inclusion of users with mobility impairments and perceptual disabilities, including users who are using assistive technologies, enabling the analysis of the compliance of modeled infrastructure to any relevant sociolegal frameworks (e.g., the Americans with Disabilities Act).
Currently, the IPVM is a mathematical framework that is being developed into a simulation software platform. The next steps of the research will involve demonstrating an application of the model in a simulation environment and then eventually calibrating and validating the model outputs to real-world sites. The IPVM framework can provide a more nuanced and realistic understanding of shared road infrastructure in spaces where there is no separating infrastructure between users. It has the potential to facilitate advanced evaluations while also providing valuable metrics aligned with the latest approaches in the field aimed at enhancing the development of more sustainable transport systems.
5. Concluding Remarks
The research presented in this paper emphasizes the growing significance of shared road infrastructure in urban settings worldwide, aiming to enhance traffic management and promote sustainability. It underscores the necessity for tools to assess shared space concepts and introduces the Integrated Pedestrian–Vehicle Model (IPVM) as a novel approach. Unlike previous efforts primarily focused on pedestrian models, the IPVM integrates various simulation techniques to depict mobility and activity in shared spaces comprehensively. Particularly noteworthy is its attention to the interaction between vehicles and pedestrians, especially in terms of long-range conflict avoidance, crucial for accurately modeling pedestrian behavior in complex environments. By simulating behavior within shared road infrastructure and providing metrics for sustainability evaluation, the IPVM offers a valuable tool for assessing the viability of shared space road proposals. Future work will involve demonstrating the IPVM and examining the effectiveness of the proposed structure for the evaluation of real-world projects, which in turn can lead to a more sustainable transport network.
Author Contributions
Conceptualization, D.S.-S. and K.P.W.; methodology, D.S.-S.; software, D.S.-S.; formal analysis, D.S.-S.; investigation, D.S.-S.; resources, D.S.-S.; data curation, D.S.-S.; writing—original draft preparation, D.S.-S.; writing—review and editing, K.P.W. and M.Z.; supervision, K.P.W. and M.Z.; project administration, K.P.W.; funding acquisition, K.P.W. All authors have read and agreed to the published version of the manuscript.
Funding
This research was funded by iMOVE Australia Cooperative Research Centre (CRC), “Optimizing Multimodal Transport Networks: Sharing the Road Space”, grant number 5-054.
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
Data supporting this study are included within the article and no further data was required to complete the review of literature.
Conflicts of Interest
The authors declare no conflicts of interest.
Appendix A. Explanation of Figure 1
Table A1.
Key to chronological topology of the literature.
References
- Hamilton-Baillie, B. Shared Space: Reconciling People, Places and Traffic. Built Environ. 2008, 34, 161–181. [Google Scholar] [CrossRef] [Scilit]
- Zeibots, M.E. Space, Time, Economics and Asphalt: An Investigation of Induced Traffic Growth Caused by Urban Motorway Expansion and the Implications It Has for the Sustainability of Cities. Ph.D. Thesis, University of Technology Sydney, Ultimo, Australia, 2007. [Google Scholar]
- Auckland City Council. Shared Space Guidelines; Auckland City Council: Auckland, New Zealand, 2017. Available online: https://infocouncil.aucklandcouncil.govt.nz (accessed on 18 September 2023).
- Firth, K. Removing traffic engineering control—The awkward truth? Traffic Eng. Control. 2011, 52, 73–79. [Google Scholar]
- Imrie, R. Universalism, universal design and equitable access to the built environment. Disabil. Rehabil. 2012, 34, 873–882. [Google Scholar] [CrossRef] [Scilit]
- Imrie, R. Auto-disabilities: The case of shared space environments. Environ. Plan. A 2012, 44, 2260–2277. [Google Scholar] [CrossRef] [Scilit]
- Holmes, C. Accidents by Design: The Holmes Report on “Shared Space” in the UnitedKingdom; London, UK, 2015; Available online: https://chrisholmes.co.uk/wp-content/uploads/2020/12/Holmes-Report-on-Shared-Space-.pdf (accessed on 15 July 2023).
- Schönauer, R.; Stubenschrott, M.; Huang, W.; Rudloff, C.; Fellendorf, M. Modeling Concepts for Mixed Traffic: Steps toward a Microscopic Simulation Tool for Shared Space Zones. Transp. Res. Rec. 2012, 2316, 114–121. [Google Scholar] [CrossRef] [Scilit]
- Helbing, D.; Molnár, P. Social force model for pedestrian dynamics. Phys. Rev. E Stat. Phys. Plasmas Fluids Relat. Interdiscip. Top. 1995, 51, 4282–4286. [Google Scholar] [CrossRef] [Scilit]
- Anvari, B. A New Microscopic Model for the Simulation of Shared Space Schemes; ProQuest Dissertations Publishing: Ann Arbor, MI, USA, 2013. [Google Scholar]
- Slack-Smith, D.G.; Wijayaratna, K.; Zeibots, M.E. Enhancing the modelling of shared spaces: Evolution of the Social Force Model. In Proceedings of the Australasian Transport Research Forum, Perth, Australia, 29 November–1 December 2023; Available online: https://australasiantransportresearchforum.org.au/wp-content/uploads/2022/05/ATRF_2023_Paper_80.pdf (accessed on 20 December 2023).
- Fiorini, P.; Shiller, Z. Time optimal trajectory planning in dynamic environments. In Proceedings of the IEEE International Conference on Robotics and Automation, Minneapolis, MN, USA, 22–28 April 1996; Volume 1552, pp. 1553–1558. [Google Scholar]
- van den Berg, J.; Lin, M.; Manocha, D. Reciprocal Velocity Obstacles for real-time multi-agent navigation. In Proceedings of the 2008 IEEE International Conference on Robotics and Automation, Pasadena, CA, USA, 19–23 May 2008; pp. 1928–1935. [Google Scholar]
- van den Berg, J.; Snape, J.; Guy, S.J.; Manocha, D. Reciprocal collision avoidance with acceleration-velocity obstacles. In Proceedings of the 2011 IEEE International Conference on Robotics and Automation, Shanghai, China, 9–13 May 2011; pp. 3475–3482. [Google Scholar]
- Rufli, M.; Alonso-Mora, J.; Siegwart, R. Reciprocal Collision Avoidance with Motion Continuity Constraints. IEEE Trans. Robot. 2013, 29, 899–912. [Google Scholar] [CrossRef] [Scilit]
- Saberi, M.; Mahmassani, H.S. Exploring Areawide Dynamics of Pedestrian Crowds: Three-Dimensional Approach. Transp. Res. Rec. 2014, 2421, 31–40. [Google Scholar] [CrossRef] [Scilit]
- Helbing, D.; Farkas, I.J.; Vicsek, T. Freezing by heating in a driven mesoscopic system. Phys. Rev. Lett. 2000, 84, 1240–1243. [Google Scholar] [CrossRef] [Scilit]
- Helbing, D.; Buzna, L.; Johansson, A.; Werner, T. Self-Organized Pedestrian Crowd Dynamics: Experiments, Simulations, and Design Solutions. Transp. Sci. 2005, 39, 1–24. [Google Scholar] [CrossRef] [Scilit]
- Helbing, D.; Tilch, B. Generalized force model of traffic dynamics. Phys. Rev. E Stat. Phys. Plasmas Fluids Relat. Interdiscip. Top. 1998, 58, 133–138. [Google Scholar] [CrossRef] [Scilit]
- Johora, F.T.; Muller, J.P. Modeling Interactions of Multimodal Road Users in Shared Spaces. In Proceedings of the 2018 21st International Conference on Intelligent Transportation Systems (ITSC), Maui, HI, USA, 4–7 November 2018; pp. 3568–3574. [Google Scholar]
- Anvari, B.; Bell, M.G.H.; Sivakumar, A.; Ochieng, W.Y. Modelling shared space users via rule-based social force model. Transp. Research. Part C Emerg. Technol. 2015, 51, 83–103. [Google Scholar] [CrossRef] [Scilit]
- Anvari, B.; Bell, M.G.H.; Angeloudis, P.; Ochieng, W.Y. Calibration and Validation of a Shared Space Model: Case Study. Transp. Res. Rec. 2016, 2588, 43–52. [Google Scholar] [CrossRef] [Scilit]
- Pascucci, F.; Rinke, N.; Schiermeyer, C.; Friedrich, B.; Berkhahn, V. Modeling of Shared Space with Multi-modal Traffic using a Multi-layer Social Force Approach. Transp. Res. Procedia 2015, 10, 316–326. [Google Scholar] [CrossRef] [Scilit]
- Pascucci, F.; Rinke, N.; Schiermeyer, C.; Berkhahn, V.; Friedrich, B. A discrete choice model for solving conflict situations between pedestrians and vehicles in shared space. arXiv 2017, arXiv:1709.09412. [Google Scholar]
- Rinke, N.; Schiermeyer, C.; Pascucci, F.; Berkhahn, V.; Friedrich, B. A multi-layer social force approach to model interactions in shared spaces using collision prediction. Transp. Res. Procedia 2017, 25, 1249–1267. [Google Scholar] [CrossRef] [Scilit]
- Rudloff, C.; Schönauer, R.; Fellendorf, M. Comparing Calibrated Shared Space Simulation Model with Real-Life Data. Transp. Res. Rec. 2013, 2390, 44–52. [Google Scholar] [CrossRef] [Scilit]
- Schiermeyer, C.; Pascucci, F.; Rinke, N.; Berkhahn, V.; Friedrich, B. Modeling and Solving of Multiple Conflict Situations in Shared Spaces; Springer International Publishing: Cham, Switzerland, 2019; pp. 451–458. [Google Scholar]
- Johora, F.T.; Müller, J.P. Zone-Specific Interaction Modeling of Pedestrians and Cars in Shared Spaces. Transp. Res. Procedia 2020, 47, 251–258. [Google Scholar] [CrossRef] [Scilit]
- Kluge, B.; Prassler, E. Recursive Probabilistic Velocity Obstacles for Reflective Navigation. In Field and Service Robotics; Springer: Berlin/Heidelberg, Germany, 2006; pp. 71–79. [Google Scholar]
- Reynolds, C. Flocks, herds and schools: A distributed behavioral model. In Proceedings of the 14th Annual Conference on Computer Graphics and Interactive Techniques, Anaheim, CA, USA, 27–31 July 1987; pp. 25–34. [Google Scholar]
- van den Berg, J.; Guy, S.J.; Lin, M.; Manocha, D. Reciprocal n-Body Collision Avoidance. In Robotics Research. Springer Tracts in Advanced Robotics; Springer: Berlin/Heidelberg, Germany, 2011; pp. 3–19. [Google Scholar]
- Wilkie, D.; van den Berg, J.; Manocha, D. Generalized velocity obstacles. In Proceedings of the 2009 IEEE/RSJ International Conference on Intelligent Robots and Systems, St. Louis, MO, USA, 10–15 October 2009; pp. 5573–5578. [Google Scholar]
- Bareiss, D.; van den Berg, J. Generalized reciprocal collision avoidance. Int. J. Robot. Res. 2015, 34, 1501–1514. [Google Scholar] [CrossRef] [Scilit]
- Snape, J.; Manocha, D. Navigating multiple simple-airplanes in 3D workspace. In Proceedings of the 2010 IEEE International Conference on Robotics and Automation, Anchorage, AK, USA, 3–7 May 2010; pp. 3974–3980. [Google Scholar]
- Snape, J.; van den Berg, J.; Guy, S.J.; Manocha, D. The Hybrid Reciprocal Velocity Obstacle. IEEE Trans. Robot. 2011, 27, 696–706. [Google Scholar] [CrossRef] [Scilit]
- Durand, N. Constant speed optimal reciprocal collision avoidance. Transp. Research. Part C Emerg. Technol. 2018, 96, 366–379. [Google Scholar] [CrossRef] [Scilit]
- Niu, H.; Ma, C.; Han, P. Directional optimal reciprocal collision avoidance. Robot. Auton. Syst. 2021, 136, 103705. [Google Scholar] [CrossRef] [Scilit]
- Alligier, R.; Gianazza, D.; Durand, N.; Olive, X. Dual-Horizon Reciprocal Collision Avoidance for Aircraft and Unmanned Aerial Systems. J. Intell. Robot. Syst. 2023, 107, 3. [Google Scholar] [CrossRef] [Scilit]
- Yeh, H.; Curtis, S.; Patil, S.; van den Berg, J.; Manocha, D.; Lin, M. Composite agents. In Proceedings of the 2008 ACM SIGGRAPH/Eurographics Symposium on Computer Animation, Dublin, Ireland, 7–9 July 2008; pp. 39–47. [Google Scholar]
- Curtis, S. Pedestrian Velocity Obstacles: Pedestrian Simulation through Reasoning in Velocity Space; ProQuest Dissertations Publishing: Ann Arbor, MI, USA, 2013. [Google Scholar]
- Dutra, T.B.; Cavalcante-Neto, J.B.; Vidal, C.A.; Musse, S.R. A Multipotential Field Model for Crowds with Scalable Behaviors. In Proceedings of the 2013 XXVI Conference on Graphics, Patterns and Images, Arequipa, Peru, 5–8 August 2013; pp. 31–38. [Google Scholar]
- Golas, A.; Narain, R.; Curtis, S.; Lin, M.C. Hybrid Long-Range Collision Avoidancefor Crowd Simulation. IEEE Trans. Vis. Comput. Graph. 2014, 20, 1022–1034. [Google Scholar] [CrossRef] [Scilit]
- Kim, S.; Guy, S.J.; Liu, W.; Wilkie, D.; Lau, R.W.H.; Lin, M.C.; Manocha, D. BRVO: Predicting pedestrian trajectories using velocity-space reasoning. Int. J. Robot. Res. 2015, 34, 201–217. [Google Scholar] [CrossRef] [Scilit]
- Ma, Y.; Manocha, D.; Wang, W. Efficient Reciprocal Collision Avoidance between Heterogeneous Agents Using CTMAT. arXiv 2018, arXiv:1804.02512. [Google Scholar]
- Ma, Y.; Manocha, D.; Wang, W. AutoRVO: Local Navigation with Dynamic Constraints in Dense Heterogeneous Traffic. arXiv 2018, arXiv:1804.02915. [Google Scholar]
- Curtis, S.; Zafar, B.; Gutub, A.; Manocha, D. Right of way. Vis. Comput. 2013, 29, 1277–1292. [Google Scholar] [CrossRef] [Scilit]
- Ren, Z.; Charalambous, P.; Bruneau, J.; Peng, Q.; Pettré, J. Group Modeling: A Unified Velocity-Based Approach. Comput. Graph. Forum 2017, 36, 45–56. [Google Scholar] [CrossRef] [Scilit]
- Helbing, D.; Jiang, R.; Treiber, M. Analytical investigation of oscillations in intersecting flows of pedestrian and vehicle traffic. Phys. Rev. E Stat. Nonlinear Soft Matter Phys. 2005, 72, 046130. [Google Scholar] [CrossRef] [Scilit]
- Zhang, X.; Zhang, P.; Guo, Y.; Jiang, X. Analysis of the influence of detouring obstacle avoidance behavior on unidirectional flow. Physica A 2023, 624, 128896. [Google Scholar] [CrossRef] [Scilit]
- Johansson, F.; Peterson, A.; Tapani, A. Waiting pedestrians in the social force model. Physica A 2015, 419, 95–107. [Google Scholar] [CrossRef] [Scilit]
- Hoogendoorn, S.; Bovy, P.H.L. Simulation of pedestrian flows by optimal control and differential games. Optim. Control Appl. Methods 2003, 24, 153–172. [Google Scholar] [CrossRef] [Scilit]
- Hoogendoorn, S.P.; Bovy, P.H.L. Pedestrian route-choice and activity scheduling theory and models. Transp. Res. Part B Methodol. 2004, 38, 169–190. [Google Scholar] [CrossRef] [Scilit]
- Moussaïd, M.; Helbing, D.; Theraulaz, G. How simple rules determine pedestrian behavior and crowd disasters. Proc. Natl. Acad. Sci. USA 2011, 108, 6884–6888. [Google Scholar] [CrossRef] [Scilit]
- Köster, G.; Hartmann, D.; Klein, W. Microscopic Pedestrian Simulations: From Passenger Exchange Times to Regional Evacuation; Springer: Berlin/Heidelberg, Germany, 2011; pp. 571–576. [Google Scholar]
- Yuan, Y.; Goñi-Ros, B.; van Oijen, T.P.; Daamen, W.; Hoogendoorn, S.P. Social Force Model Describing Pedestrian and Cyclist Behaviour in Shared Spaces. In Traffic and Granular Flow’17; Springer: Cham, Switzerland, 2019; pp. 477–486. [Google Scholar]
- Treiber, M.; Hennecke, A.; Helbing, D. Congested traffic states in empirical observations and microscopic simulations. Phys. Rev. E Stat. Phys. Plasmas Fluids Relat. Interdiscip. Top. 2000, 62, 1805–1824. [Google Scholar] [CrossRef] [Scilit]
- Dijkstra, E.W. A note on two problems in connexion with graphs. Numer. Math. 1959, 1, 269–271. [Google Scholar] [CrossRef] [Scilit]
- Hart, P.E.; Nilsson, N.J.; Raphael, B. A Formal Basis for the Heuristic Determination of Minimum Cost Paths. IEEE Trans. Syst. Sci. Cybern. 1968, 4, 100–107. [Google Scholar] [CrossRef] [Scilit]
- Anvari, B.; Bell, M.G.H.; Angeloudis, P.; Ochieng, W.Y. Long-range Collision Avoidance for Shared Space Simulation based on Social Forces. Transp. Res. Procedia 2014, 2, 318–326. [Google Scholar] [CrossRef] [Scilit]
- Levien, R.L. From Spiral to Spline: Optimal Techniques in Interactive Curve Design; ProQuest Dissertations Publishing: Ann Arbor, MI, USA, 2009. [Google Scholar]
- Brander, D.; Bærentzen, J.A.; Fisker, A.-S.; Gravesen, J. Bézier curves that are close to elastica. Comput. Aided Des. 2018, 104, 36–44. [Google Scholar] [CrossRef] [Scilit]
- Gravesen, J. Adaptive subdivision and the length and energy of Bézier curves. Comput. Geom. Theory Appl. 1997, 8, 13–31. [Google Scholar] [CrossRef] [Scilit]
- Nicholl, T.M.; Lee, D.T.; Nicholl, R.A. An efficient new algorithm for 2-D line clipping: Its development and analysis. ACM SIGGRAPH Comput. Graph. 1987, 21, 253–262. [Google Scholar] [CrossRef] [Scilit]
- Köster, G.; Treml, F.; Gödel, M. Avoiding numerical pitfalls in social force models. Phys. Rev. E Stat. Nonlinear Soft Matter Phys. 2013, 87, 063305. [Google Scholar] [CrossRef] [Scilit]
- Park, J.H.; Rojas, F.A.; Yang, H.S. A collision avoidance behavior model for crowd simulation based on psychological findings. Comput. Animat. Virtual Worlds 2013, 24, 173–183. [Google Scholar] [CrossRef] [Scilit]
- Carlsen, L.; Bruggemann, R. The 17 United Nations’ sustainable development goals: A status by 2020. Int. J. Sustain. Dev. World Ecol. 2022, 29, 219–229. [Google Scholar] [CrossRef] [Scilit]
- Anvari, B.; Daamen, W.; Knoop, V.L.; Hoogendoorn, S.P.; Bell, M.G.H. Shared Space Modeling Based on Social Forces and Distance Potential Field; Springer International Publishing: Cham, Switzerland, 2013; pp. 907–916. [Google Scholar]
- Bareiss, D.; van den Berg, J. Reciprocal collision avoidance for robots with linear dynamics using LQR-Obstacles. In Proceedings of the 2013 IEEE International Conference on Robotics and Automation, Karlsruhe, Germany, 6–10 May 2013; pp. 3847–3853. [Google Scholar]
- Blue, V.J.; Adler, J.L. Emergent Fundamental Pedestrian Flows from Cellular Automata Microsimulation. Transp. Res. Rec. 1998, 1644, 29–36. [Google Scholar] [CrossRef] [Scilit]
- Blue, V.J.; Adler, J.L. Cellular Automata Microsimulation of Bidirectional Pedestrian Flows. Transp. Res. Rec. 1999, 1678, 135–141. [Google Scholar] [CrossRef] [Scilit]
- Baglietto, G.; Parisi, D.R. Continuous-space automaton model for pedestrian dynamics. Phys. Rev. E Stat. Nonlinear Soft Matter Phys. 2011, 83, 056117. [Google Scholar] [CrossRef] [Scilit]
- Campanella, M.; Hoogendoorn, S.; Daamen, W. A hybrid time-based and event-driven management of pedestrians in micro-simulation models. In Proceedings of the 10th International Conference on Computers in Urban Planning and Urban Management, Foz do Iguaçu, Paraná, Brasil, 11–13 July 2007. [Google Scholar]
- Campanella, M.; Hoogendoorn, S.; Daamen, W. The nomad model: Theory, developments and applications. Transp. Res. Procedia 2014, 2, 462–467. [Google Scholar] [CrossRef] [Scilit]
- Chraibi, M.; Seyfried, A.; Schadschneider, A. Generalized centrifugal-force model for pedestrian dynamics. Phys. Rev. E Stat. Nonlinear Soft Matter Phys. 2010, 82, 046111. [Google Scholar] [CrossRef] [Scilit]
- Hartmann, D. Adaptive pedestrian dynamics based on geodesics. New J. Phys. 2010, 12, 043032. [Google Scholar] [CrossRef] [Scilit]
- Hoogendoorn, S.P.; Bovy, P.H.L. Dynamic user-optimal assignment in continuous time and space. Transp. Res. Part B Methodol. 2004, 38, 571–592. [Google Scholar] [CrossRef] [Scilit]
- Helbing, D.; Keltsch, J.; Molnár, P. Modelling the evolution of human trail systems. Nature 1997, 388, 47–50. [Google Scholar] [CrossRef] [Scilit]
- Ishaque, M.M.; Noland, R.B. Behavioural Issues in Pedestrian Speed Choice and Street Crossing Behaviour: A Review. Transp. Rev. 2008, 28, 61–85. [Google Scholar] [CrossRef] [Scilit]
- Johansson, A.; Helbing, D.; Shukla, P. Specification of the social force pedestrian model by evolutionary adjustment to video tracking data. Adv. Complex Syst. 2007, 10, 271–288. [Google Scholar] [CrossRef] [Scilit]
- Kesting, A.; Treiber, M.; Helbing, D. General Lane-Changing Model MOBIL for Car-Following Models: Traffic Flow Theory 2007. Transp. Res. Rec. 2007, 1999, 86–94. [Google Scholar] [CrossRef] [Scilit]
- Kesting, A.; Treiber, M.; Helbing, D. Enhanced intelligent driver model to access the impact of driving strategies on traffic capacity. Philos. Trans. R. Soc. Lond. Ser. A Math. Phys. Eng. Sci. 2010, 368, 4585–4605. [Google Scholar] [CrossRef] [Scilit]
- Kretz, T.; GroßE, A.; Hengst, S.; Kautzsch, L.; Pohlmann, A.; Vortisch, P. Quickest Paths in Simulations of Pedestrians. Adv. Complex Syst. 2011, 14, 733–759. [Google Scholar] [CrossRef] [Scilit]
- Kretz, T. Pedestrian traffic: On the quickest path. J. Stat. Mech. 2009, 2009, P03012. [Google Scholar] [CrossRef] [Scilit]
- Kneidl, A.; Hartmann, D.; Borrmann, A. A hybrid multi-scale approach for simulation of pedestrian dynamics. Transp. Res. Part C Emerg. Technol. 2013, 37, 223–237. [Google Scholar] [CrossRef] [Scilit]
- Kluge, B.; Prassler, E. Reflective navigation: Individual behaviors and group behaviors. In Proceedings of the IEEE International Conference on Robotics and Automation, 2004. Proceedings. ICRA ’04, New Orleans, NJ, USA, 26 April–1 May 2004; IEEE: Piscataway, NJ, USA, 2004; Volume 4174, pp. 4172–4177. [Google Scholar]
- Liu, Z.; Jiang, Z.; Xu, T.; Cheng, H.; Xie, Z.; Lin, L. Avoidance of High-Speed Obstacles Based on Velocity Obstacles. In Proceedings of the 2018 IEEE International Conference on Robotics and Automation (ICRA), Brisbane, QLD, Australia, 21–25 May 2018; IEEE: Piscataway, NJ, USA, 2018; pp. 7624–7630. [Google Scholar]
- Lakoba, T.I.; Kaup, D.J.; Finkelstein, N.M. Modifications of the Helbing-Molnár-Farkas-Vicsek Social Force Model for Pedestrian Evolution. Simulation 2005, 81, 339–352. [Google Scholar] [CrossRef] [Scilit]
- Moussaïd, M.; Helbing, D.; Garnier, S.; Johansson, A.; Combe, M.; Theraulaz, G. Experimental study of the behavioural mechanisms underlying self-organization in human crowds. Proc. R. Soc. B Biol. Sci. 2009, 276, 2755–2762. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Moussaïd, M.; Perozo, N.; Garnier, S.; Helbing, D.; Theraulaz, G. The walking behaviour of pedestrian social groups and its impact on crowd dynamics. PLoS ONE 2010, 5, e10047. [Google Scholar] [CrossRef] [Scilit]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2024 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).