


Abstract
DC microgrids (DC MGs) offer advantages such as efficiency, control, cost, reliability, and size compared to AC MGs. However, they often operate with numerous constant power loads (CPLs), exhibiting a negative incremental impedance characteristic that can lead to instability. This instability weakens stability boundaries and reduces system damping, especially when dealing with pulsed power loads (PPLs) on electric aircraft, ships, and cars. Linear controllers may not ensure stability across various operations, causing voltage dips and potential system instability. To secure DC/DC converter functionality and comply with impedance specifications, it is crucial to consider minor loop gain in control strategies and stabilization techniques. Employing diverse methods to decrease minor loop gain in DC/DC converters is essential. A comprehensive evaluation, including strengths, weaknesses, opportunities, and threats (SWOT) analysis, is conducted to assess control strategies, stabilization techniques, and stability standards for different DC/DC converters, identifying SWOT.
1. Introduction
Power electronic systems have seen widespread adoption in recent years, which has been driven by the integration of DC interfaces into conventional AC power system networks. These systems facilitate bidirectional power conversion between DC and AC and are typically positioned between source and load circuits. Additionally, they play a role in enhancing the reliability and stability of distributed energy resources (DERs).
Power electronic converters are categorized into four types: rectifiers, inverters, choppers, and cycloconverters, each with distinct characteristics and applications [1,2]. These converters exhibit higher efficiency, faster dynamics, and smaller physical sizes compared to mechanical systems with similar power ratings. However, effective control and stabilization are essential, since certain loads can induce instability in converter-based grids.
The power electronics market is expected to grow from USD 43.3 billion in 2022 to exceed USD 94.21 billion by 2032 [2,3,4]. A number of industries are developing applications for DC/DC converters in DC microgrids (MGs), which consist of two systems—one of them acting as the master and the other as the slave—that use linear droop control with supervisory control and data acquisition (SCADA) [3]. The increased use of power electronics in consumer electronics and power-generating industries is anticipated to drive market demand.
DC MGs commonly rely on traditional converters like buck, boost, and buck/boost noninverting buck/boost converters and different topologies as they are described in Section 2 [4]. However, specific applications necessitate interfacing DC/DC converters with significant step-up or step-down ratios, making multi-level converters essential. Concerning control, DC/DC converters in DC MGs face two primary challenges [5]. The first challenge is related to instability caused by constant power loads (CPLs) with tightly regulated power electronics loads. CPLs exhibit I-V characteristics corresponding to negative incremental impedance [4,5]. The reduction in stability margin in the interaction between feeders and CPLs, attributed to negative incremental impedance, often leads to instability and decreased system damping [6].
The negative incremental impedance of CPLs consistently remains negative, as depicted in Figure 1, even though the impedance’s instantaneous value is always positive, as shown in Figure 1. This negative incremental impedance feature could deteriorate system performance, potentially leading to underdamped or unstable oscillations when the system’s CPL and a source converter are coupled in a cascade. Furthermore, the voltage exponentially decreases, while the current increases exponentially. Different control strategies, including virtual capacitors, virtual impedance, pole positioning techniques, and loop cancellation approaches, have been employed to stabilize DC/DC converters supplying CPLs and PPLs [7].
Figure 1.
Negative incremental impedance behavior due to CPLs.
Linear controllers, relying on small signal models, are limited to ensuring small signal stability solely at the operating point, as the nonlinearity of CPLs hinders their effectiveness beyond that point. In the presence of large signals, these strategies may become ineffective, leading to system instability. To stabilize the system from the perspective of large-signal response, advanced control techniques need exploration. The second issue is the pulsed power load (PPL) problem, impacting MGs similarly to electric airplanes, ships (classification and characteristics of ships are not reviewed in this research), and cars [6,8]. PPLs consume a significant amount of energy quickly and can potentially shift the MG far from the stationary operating point due to their high-power characteristics. Traditional linear control approaches are incapable of ensuring system stability over wider operating ranges, possibly resulting in significant voltage sags and system instability.
Power filter-based control, adaptive current voltage control, and limit-based voltage control are some of the technical PPLs-related approaches that researchers have developed and described in [7]. However, even though faster dynamics, system stabilization, and optimal performance can be achieved by advanced control technologies, existing linear control methods are unable to do so. To stabilize the system in a large-signal sense, advanced control strategies will need to address the aforementioned challenges posed by DC/DC converters to ensure system stability.
Various factors influence the selection of MG control topology, including control layers, communication topology, and the type of loads [9]. MG control schemes can be classified into four groups based on the type of controller [10], location, structure, and communication link [11]. These systems are centralized, decentralized, distributed, and hierarchical [12]. Many studies recommend hierarchical control as a solution to challenges arising from integrating distributed energy resources into MGs and coordinating MGs in a cluster [13]. This approach involves multiple control tiers, enhancing the flexibility and efficiency of the MG [14]. The control system has three levels: primary, secondary, and tertiary. They regulate DC microgrids that consist of various distributed energy resources. The red cables indicate positive polarity, and the blue cables indicate negative polarity, as shown in Figure 2. Each task is performed at the designated level with communication between them to achieve overall objectives [9].
Figure 2.
Hierarchical control of DC MGs.
However, challenges arise, particularly concerning the type of loads, as DC MGs can supply various loads such as CPLs, resistive loads, and PPLs, significantly affecting network stability. Technical losses mitigation is not considered at the secondary level, as power flow depends on distance, influencing the voltage at the sending and receiving ends of a transmission line [13]. Voltage and current are controlled at the primary level using different controllers, ensuring stability criteria are met. Another concern is the need for new grid codes for converter-based grids, requiring further development [15].
The future network will be dominated by numerous DERs due to various government initiatives. Integrating DERs will necessitate involvement from technologies like power electronics, communication topology, fault monitoring, and the predictive maintenance of MGs. Hence, a comprehensive review paper is needed to encompass DC MG control strategies and stabilization techniques along with challenges, opportunities, and prospects.
This review paper critically examines the existing literature, pinpointing outstanding and emerging trends requiring attention. The contribution of this review paper is summarized as follows: it provides a comprehensive review of various control strategies and stabilization techniques for DC MGs, covering the advantages, disadvantages, challenges, and limitations of each method. It also explores future trends addressing issues related to negative incremental impedance and power imbalance. Detailed recommendations and prospects are provided, incorporating the strengths, weaknesses, opportunities, and threats (SWOT) analysis [16].
1.1. Investigated Topologies for DC/DC Converters and Most Usable Types
DC/DC converters, featuring various topologies, play a crucial role in aligning voltage levels, managing power, and facilitating efficient energy transfer within electronic systems [17]. They enable the assimilation of diverse power sources, offer galvanic isolation, and contribute to the creation of compact and lightweight designs [15]. These DC/DC converters are indispensable components in renewable energy systems, battery charging, and the customization of power solutions to meet unique application requirements.
The classification of DC/DC converters includes single input and single output (SISO) configurations along with their respective applications [4,5]. Additionally, multiple input and multiple output (MIMO) setups are detailed, outlining their applications [6,7,8,18,19,20]. Further, single input and multiple output (SIMO) configurations are explored along with their applications in [9,10,17,21,22]. The multiple input and single output (MISO) converters is also covered, providing detailed insights into their applications [11,12,13,14].
1.2. Typical Ratings of DC Microgrids
The requirements for DC MGs are currently in the early stages of development. Fortunately, specific values for various purposes are provided, such as 5 V, 12 V, 48 V, 380–400 V [23], and 1500 V [24,25]. Additional insights into their application domains, advantages, shortcomings, and current standards can be found in [23,26].
2. Control Strategies for DC/DC Converters in DC MGs Applications
DC/DC converters are gaining increased importance for effectively integrating various types of DERs, such as wind energy conversion systems, solar power plants, energy storage, fuel cells, and for supplying different loads like CPLs, PPLs, and resistive loads. In Figure 3, a DC MG is illustrated with different DERs, including a fuel cell, battery energy storage, photovoltaics (PVs), and wind with doubly fed induction generators (DFIG) and converters connected through a DC bus line. DERs must comply with grid integration rules, encompassing fault ride-through capability (FRTC), voltage stabilization, and excessive energy management.
Figure 3.
DC MG with CPLs and PPLs.
Furthermore, Figure 3 illustrates the DC MG supplying CPLs and PPLs, generating instability that can be mitigated through the development of controllers and prototypes. Please note in Figure 3, red cables represent the positive polarity in direct current (DC) while green cables represent the negative polarity. On the other hand, red, yellow, and blue cables indicate that the load is powered by three cables (two phases, one neutral) and yellow is a phase in alternating current (AC). Figure 4 summarizes control strategies and stabilization techniques for DC MGs, addressing stability issues associated with negative incremental impedance. It depicts the impact of CPLs and PPLs and how they can be managed. It is important to note that Figure 4 is based on the authors’ understanding and analysis of various control strategies and stabilization techniques for DC MGs without using any specific resource or reference [26].
Figure 4.
Proposed diagram for control strategies and stabilization techniques.
Several advanced control strategies for DC MGs aim to mitigate the effects of negative incremental impedance [27,28]. These strategies include Model Predictive Control (MPC), Backstepping Control, Sliding Mode Control (SMC), Passivity-Based Control (PBC), Artificial Intelligence-based Control, Linear Droop Control, Nonlinear Droop Control, Piecewise Linear Droop Control, and Synergetic Control. Table 1 summarizes the advantages, disadvantages, working principles, applications, and practical cases of each control strategy and provides a corresponding discussion.
Table 1.
Summary of relevant control strategies for DC/DC converters in DC MGs applications.
2.1. Model Predictive Control (MPC)
An effective method for significantly improving tracking performance is Model Predictive Control (MPC), which is classified as one of the nonlinear control strategies currently applied in DC/DC converters [66]. This approach has garnered considerable attention in power converters and motor drive systems [67,68]. In MPC, achieving high-precision tracking relies on having an accurate and effective system model, which is a challenge persistently hinderd by system disturbances and uncertainties in model parameter realization [61,66].
MPC operates with the present state of the system as its starting point [67]. The control input at the next discrete timestep is determined through optimization over a finite time horizon [9,20,24,69].
By resolving the optimization equation in a receding horizon, the basic idea of MPC could be stated as follows:
Subject to
The system model, represented by Equations (1)–(4) with state vector x, input vector u, and output vector y, specifies the constraints on state and vector control. Discrete-time MPC utilizes Equation (1), while continuous-time MPC operates on a continuous-time model defined by a distinct equation. Nonetheless, both discrete and continuous-time MPC follow the same basic principle [68].
Subject to
where Equation (5) denotes the cost function for continuous-time MPC in the receding horizon, while Equation (6) delineates the constraints on the state and control vectors. Equations (7) and (8) represent a linear dynamic model, where is the state vector of dimension . are matrices. The control input is represented by at a future time [70]. The process and guidelines for designing new algorithms based on MPC are depicted and detailed in [26,27,66].
2.2. Backstepping Control (BSC)
The backstepping control (BSC) method is relatively new in nonlinear control theory. It is a nonlinear control approach that allows for the sequential and systematic construction of stabilizing Lyapunov functions through backstepping. Unlike other methods, it is less restrictive, as it does not necessitate a linear model for the controlled system [36,66]. The application of this nonlinear control scheme is driven by the system’s inherent nonlinearity. In the presence of these nonlinearities, the control law provided by backstepping yields a reliable and accurate output [71,72]. A key advantage of this method lies in its ability to handle uncertainties, load disturbances, and input variations effectively.
The BSC method is particularly suitable for large signal stabilization through the recursive Lyapunov design process [73]. This involves creating an observer to ensure accurate tracking even in the presence of disturbances and uncertainties. A noteworthy distinction between BSC and MPC is the BSC method’s ability to estimate model uncertainties and constant power load (CPL) disturbances [31,32].
DC/DC converters are commonly modeled as second-order systems. Therefore, the design of second-order systems using backstepping is briefly discussed. The nonlinear system under consideration is presented in Equations (9) and (10).
where and is the command or system input, is an analytical function of and stands for the output of the system; represent the infinitely differentiable vectors [74]. After applying feedback linearization theory to analyze the system under various output functions, the closed-loop system is stabilized using backstepping sliding mode control.
2.3. Sliding Mode Controller (SMC)
This Sliding Mode Control (SMC) strategy has demonstrated positive effects on load and input voltage variations while maintaining dynamic responsiveness, at least comparable to conventional current control strategies [75]. Research findings indicate that DC MGs supplying shipboard power systems are vulnerable to instability due to incremental impedance created by the presence of CPLs linked to the DC bus, as illustrated in Figure 5 [34,35]. According to studies in the literature, the closed-loop control system exhibits appealing features, including resistance to shocks and low sensitivity to parameter fluctuations when the sliding mode is enforced [38,40,76].
Figure 5.
DC MGs supplied shipboard.
A drawback of the standard SMC is the switching frequency variation, which could complicate filter construction and worsen noise levels. To address this, fixed switching frequency methods are recommended, involving the calculation of a duty ratio based on an SMC block and its application to pulse width modulation (PWM). After the SMC block selects the appropriate control signal for PWM-based SMC, a PWM block should be integrated into the control diagram to trigger the converter’s gate [77].
Advanced SMC proves to be more resistant to system uncertainties and less prone to instabilities during the steady-state period compared to traditional SMC. The fixed switching frequency SMC is further enhanced by the development of digital SMC, ensuring current-limiting capabilities. Research suggests that PWM-based SMC utilizes a nonlinear switching function to address instability caused by negative incremental impedance in DC/DC MGs supplying mixed loads [39,78]. The scientific analysis encompasses several breakthroughs in DC/DC converters, one notable example being the exploration of PWM with SMC for boost converters [79]. The research demonstrates how this control system can be easily implemented using simple analogy circuits [80].
The primary challenge lies in designing a precise output feedback controller for linear time-invariant systems with a focus on optimizing passivity in both continuous and discrete time. A novel approach involves leveraging SMC in a mechanical system defined by simple port Hamiltonian systems [81]. Through this, the analysis unveils a unique category of controllers rooted in passivity, exhibiting properties that mirror those of sliding mode controllers.
Therefore, Figure 5 represents DC MGs composed of different DERs and supplying a shipboard load. However, the shipboard load causes power imbalance, since it is considered as PPL due to its intrinsic characteristics [82]. The color lines in Figure 5 are the same representation as in Figure 3.
The fundamental concept of SMC is to construct a specific sliding manifold in its control law, directing the sliding surface of the state variables toward a selected operating point. The switching function, employed by the control law for a single-switch DC/DC converter, is represented in Equation (11) as follows:
where stands for the logic state of the converter’s power switch and is the instantaneous sliding surface. Moreover, it can be modified when a second-order controller is involved, and the equation can be expressed in Equation (12) as follows:
where represent the sliding coefficients.
Meanwhile, and stand for the desired state feedback variables to be managed.
A manifold (sliding plane) is obtained if the sliding surface is enforced to be equal to zero .
2.4. Passivity-Based Control (PBC)
The research findings suggest that Proportional-Based Control (PBC) is a nonlinear control method that offers simplicity, efficiency, effectiveness, and ease of use. For ensuring the stability of DC/DC converters powering CPLs, Proportional Derivative (PD) controllers are utilized [76]. Consequently, PBC is recommended for a buck converter with CPLs, but the impact of adding resistors in series, parallel, or cascade with inductors and capacitors (LCC) has not been discussed [83]. Additionally, it is demonstrated that the equilibrium point is only locally stable because duty ratio values greater than unity are mathematically not representable [84]. A Proportional Integral Derivative (PID) controller is required for controlling and stabilizing the loops based on PBC, and its gains can be adjusted manually or online, relying on filter calculation methods [43,48].
Furthermore, PBC and an adaptive interconnection with a PID controller are recommended to ensure passivity in boost and buck converters supplying CPLs, given their significant effectiveness in mitigating voltage variations and reducing the effects of damping [44,45]. PBC is a nonlinear control approach based on the concept of energy conservation, meaning that the energy supplied should be equal to the sum of energy stored and dissipated [85]. If the system is passive, its energy balance can be expressed through Equation (13), considering the energy supplied, stored, and dissipated, as follows:
where stands for energy supplied, represents the energy stored, stands for energy dissipated, is an input and stands for output of the system.
2.5. Artificial Intelligence-Based Control (AI)
Fuzzy logic, artificial neural networks [77,86], artificial bee swarm algorithm, adaptive neural-fuzzy inference systems, fuzzy clustering, and heuristics have been employed to stabilize DC MGs [87]. These methods do not require an accurate model representation, and the variables of artificial intelligence (AI) can be tuned online. The system’s impedance is determined by the operating point, which may exhibit different profiles if modified. In some cases, the advanced controllers described previously may be insufficient to address this challenge.
When the operating point lacks fixation, linear droop regulation imposes some limitations on load sharing and current sharing, which is particularly exacerbated by time-varying cable resistances. To mitigate these drawbacks, our work proposes a distinctive approach by integrating AI-based methods with other controllers in the islanded electric aircraft (MEA) Electric Power Systems (EPS) DC MG. This novel design maximizes shared power and adjusts voltage on the bus using unique adjustment factors [64,88].
In addressing challenges within DC MGs, such as supplying CPLs with negative incremental impedance, the utilization of backstepping control with Artificial Neural Networks (ANNs) proves effective. The adaptability of ANNs, being trainable, enables the controller to adjust to various MG changes and uncertainties without reliance on a fixed operating point. This adaptive strategy enhances control efficacy in dynamic microgrid settings [89].
2.6. Synergetic Control (SC)
The synergetic control (SC) approach is a nonlinear method based on concepts from nonlinear dynamic dissipative systems. SC and SMC share a control methodology involving the design of a linear manifold to guide the system’s states toward the desired stable point. The advantages of the synergetic control system described here include finite-time convergence, resistance to variable fluctuations, and the absence of stuttering issues [90].
SC is particularly suitable for systems operating with nonlinearities and uncertainties, finding application in robotics, aircraft, chemical processes, mechatronics, and renewable energy. It excels in situations requiring fast convergence, resilience to variable modifications, and avoidance of chattering issues. Practical examples of applying synergetic control include achieving accurate motion in robotics, enhancing stability in aeronautical structures, optimizing chemical processes, improving mechatronics performance, and optimizing energy systems. In general, synergetic control provides a comprehensive solution for a wide range of dynamic systems, offering stability, fast integration, and robustness in various use cases.
2.7. Linear, Nonlinear and Piecewise Linear Droop Controllers
Linear controllers are recommended for DC/DC converter applications in DC MGs when the operating point is assumed to be constant, which is a condition seldom found when disturbances are ignored [91]. However, relying on such a system is not practical because the system’s parameters are subject to change due to various causes [60]. The nonlinear droop controller takes into account load sharing, voltage regulation, efficiency, and stability, and its analysis can be performed using tools like bode diagrams, Nyquist plots, and root locus [92,93].
Nevertheless, a piecewise linear droop control (PLDC) is proposed to achieve optimal and balanced performance for both voltage regulation and current sharing in DC MG [94]. This approach acts as a bridge between linear droop controllers and nonlinear droop controllers, allowing for the derivation of polynomial droop controllers from linear ones. Additionally, the performance and robustness vary when the system is supplying light loads, medium loads, and heavy loads [57,58,60].
3. Stability Analysis of DC/DC Converters in DC MGs Applications
Ensuring the dynamic stability of DC MGs is essential for enhancing their safety and reliability. To improve the system’s robustness and dynamic performance, it is crucial to implement control strategies and stabilization methods that align with stability criteria, ensuring system stability and meeting impedance specifications. Specifically, adherence to the Nyquist stability criterion is crucial with a focus on the minor loop gain. When dealing with a grid with interconnected converters, applying the Nyquist stability criterion across the interconnection becomes necessary [95].
Moreover, the negative incremental impedances resulting from the presence of both CPLs and PPLs create a power imbalance. The rapid energy consumption in a short time can potentially degrade the stability and reliability of DC/DC converters in DC MG applications, consisting of numerous interconnected feedback-controlled switching converters. Consequently, stability analysis for these systems is a crucial design element. This article reviews various stability criteria and provides a table summarizing the benefits and drawbacks of each stability criterion [59,60,96]. The various stability criteria developed so far are listed and schematically shown in Figure 6, the Middlebrook criterion and other stability criteria, considered as its extensions, are described in [56,57].
Figure 6.
Some stability criteria boundaries.
3.1. The Middlebrook Criterion
Middlebrook was the first to recognize that specific pairings of the output and input impedances of successive subsystems could lead to instability, resembling a negative incremental impedance oscillator. In practical applications, network components, especially power electronic converters and their input filters, may embody these successive subsystems [63,97]. It was accordingly suggested that the output impedances of the filters should be significantly lower than their input impedance across frequency ranges (boundaries), i.e., or equivalently . stands for the minor loop gain of the system and is considered one of stability requirements, and it is shown in Figure 7.
Figure 7.
Interconnection of two stable independent systems.
Adhering to this design principle not only maintains system stability but also provides an additional advantage of dynamic decoupling between the converter and its input filter. The stability of the system relies primarily on the ratio between output impedance and input impedance, which are represented by and (refer to Figure 7) as stable transfer functions.
The Nyquist stability criterion can be employed to analyze the system’s stability based on mathematical modeling and a state-space model. The developed matrix must satisfy the Nyquist requirements, as illustrated in Figure 8, the areas that include the (−1, j0) point are restricted by ensuring that the contour of TMLG stays outside certain restricted areas, implying that system stability can be guaranteed. Design criteria and formulations can be specified based on how the forbidden regions are defined. Figure 7 represents the interconnection of two stable independent systems, and their stability can be analyzed via Equations (14) and (15).
Figure 8.
Nyquist plot showing stable system versus unstable system.
Figure 8 illustrates two graphs: a blue graph indicating a stable system and a red graph representing an unstable system in the presence of a disturbance. These graphs are plotted using the quantity N, which signifies the number of encirclements. A positive N denotes anticlockwise encirclement of the point (−1,0), while a negative N suggests clockwise encirclement of the same point. In this context, Z represents the number of closed-loop poles in the right-half plane (RHP), while P indicates the number of open-loop poles in the same plane. These conditions are essential for satisfying the Nyquist stability criterion.
3.2. Gain Margin and Phase Margin Criterion (GMPM)
One limitation of the Middlebrook stability criterion is its tendency to advocate larger filter components than necessary for stability. Consequently, researchers have proposed alternative criteria to mitigate Middlebrook’s conservatism and reduce the size of filter components. To address these concerns, the gain margin and phase margin criteria have been incorporated to overcome these challenges. This involves maintaining the required minimum gain and phase margins within a specific frequency range |||| >> |||| to adhere to the Nyquist criterion.
The Middlebrook Extra Theorem (EET) can be employed to analyze the effects of the input filter on the system. However, it is crucial to emphasize that information regarding both magnitude and phase margins is essential. It is possible for to appear positive while the system remains unstable. This phenomenon can be observed using the SISO tool available in MATLAB R2023b [63,68,96,97].
3.3. The Opposing Argument Criterion
The earlier stability criteria are suitable for systems with a single connected load. However, the opposing argument criterion proves more powerful as it can be applied to systems with both linear and nonlinear loads. To assess the stability of the system using the opposing argument criterion, the TMLG for each load subsystem must be determined and then aggregated to obtain equivalent TMLG gains [96,97]. Figure 8 illustrates a system with n loads. The stability of DC/DC converters connected in parallel or in series is determined by the impedances of each load with the total load impedances calculated by adding together each of the n individual load impedances in parallel, as expressed through the combination of all n individual impedances, i.e., or using the Y-parameter model and G-parameter model to analyze the impact of impedances on the system [98]. The system, represented in Figure 8, can have an equivalent minor-loop gain (GMLG) calculated by aggregating the individual TMLG gains for each load, which are determined as Equation (16) as follows:
Equation (16) represents the equivalent minor loop gain of each load in Figure 8. The minor loop gain can be determined by considering the ratio between output impedance and input impedance, and vice versa, if [99], and it can be calculated considering the transfer function of the system.
3.4. Energy Source Analysis Consortium (ESAC) Criterion
When multiple subsystems are interconnected, and their components are arranged in various patterns (which can differ for a given type of subsystem due to the connections and types of transmission lines), the stability requirement becomes especially relevant. Inconsistencies in these configurations could influence the outcome of the system’s stability study. The ESAC criterion utilizes a three-dimensional representation in the admittance space, incorporating frequency, phase, and magnitude. By examining the subsystem impedance and forbidden region, this criterion can determine the input load impedance of a system for a particular frequency range. Then, as long as the load admittance space does not fall within a prohibited area, system stability can be guaranteed [63,96].
Because it allows for the specification of both gain and phase margins and occupies less space in the s-plane than the Magnitude and Phase Margin (GMPM) criterion, as illustrated in Figure 8, the ESAC criterion is akin to the GMPM criterion. Additionally, as depicted in Figure 8, the forbidden region comprises two-line segments that start at infinity with parallel negative real axes and end at the unit circle’s perimeter [100]. Two additional line segments begin at the unit circle and end at , connecting these two segments. The ESAC criterion has the advantage of further opening up the s-plane, reducing artificial conservativeness even more [100].
3.5. Three-Step Impedance Criterion (TSIC)
The three-step impedance criteria involve the following steps:
- Replacement of Downstream Subsystems: Initially, the downstream subsystems are substituted with mapped pure impedances using mathematical transformations [74,96].
- Impedance Measurement: The output impedances of the upstream subsystem (s) and the input impedance of the downstream subsystem are used to calculate the equivalent impedance (denoted as of the entire network [74,96].
- System stability analysis: After determining the transfer function between the output voltage and the input voltage, and the provided in Equation (17), the stability of the system is analyzed as follows:where and represent the extended minor-loop gain, the input impedances of the downstream n subsystems, and the output impedance of the upstream subsystem connected to downstream n subsystems, respectively [101]. (The input subsystems are interconnected with output subsystems through a single bus bar arrangement and PWM for switching operations.) The Nyquist plot is employed to determine the stability condition. Specifically, if the extended minor-loop gain Nyquist plot does not encircle the point (−1, 0), the system is stable [63,74,96].
3.6. μ-Sensitivity Criterion
The μ-sensitivity stability analysis considers crucial factors such as linear fractional transformation (LFT), structured singular value μ, skewed-structured singular value (ν), and sensitivity [102]. The μ-sensitivity-based stability analysis follows these steps:
- (a)
- Obtain a symbolically linearized model of the system at the equilibrium point. If the system matrix contains nonlinearities, replace them with their approximate polynomial form before creating an LFT-based model.
- (b)
- Compute sensitivities. The upper LFT represents the transfer function from signals describing all uncertainties in the system’s outputs and inputs, while the lower LFT represents the transfer function from signals when closing the lower loop [68,70].
The μ sensitivity criterion is applicable to the DC/DC converter supplying CPLs and a Proportional Integral (PI) controller with a filter (LC). This method provides a more comprehensive and direct insight into the impact of system components on stability analysis compared to certain stability criteria [96,103].
3.7. Phase-Plane Analysis
The solutions of the system are typically visualized through phase-plane analysis, providing insights into how the system dynamics evolve over time [70,103]. This method can be utilized to examine the closed-loop behavior of converters supplying CPLs. While it does not provide a specific solution to the differential equations describing a system’s behavior [104], the phase-plane analysis method is suitable for large signal stability analysis. For DC/DC converters supplying CPLs, voltage and current loops should be incorporated to enhance system stability. The use of a Proportional, Integral and Derivative (PID) controller will also yield a steady-state inaccuracy between the reference and tracking signals [105].
3.8. Bifurcation Analysis
Bifurcation analysis is a powerful tool for studying the steady-state nonlinear dynamics of systems with bifurcations occurring in both continuous and discrete systems. The stability analysis of DC/DC converters supplying CPLs can be identified by searching for Hopf bifurcation points based on Jacobian matrices [106]. Therefore, the system’s stability is examined by considering the eigenvalues and numerically computing bifurcation parameters. Consequently, the filter parameters and power loads should be considered, as they can impact system stability [107]. This information can be effectively used by system designers to ensure the stability of the actual system [108].
3.9. Kalman–Yakubovich–Popov Lemma Stability Criterion
The Kalman–Yakubovich–Popov (KYP) lemma stability criterion develops a limited frequency KYP lemma for singular fractional systems (SFOSS), derives a bounded real lemma in the L∞-norm, and creates a controller to improve the L∞ performance index of SFOSS within certain frequency ranges [109]. Moreover, the KYP has been identified as one of the stability criteria to analyze nonlinear systems when applied to CPLs [110]. The system becomes stable when it satisfies the KYP stability criterion, as described in [111,112].
3.10. Lyapunov Stability Criterion
Selecting a Lyapunov function to characterize system energy constitutes the Lyapunov stability requirement for DC/DC converters in DC MGs. The Lyapunov stability criterion is employed to assess the system’s stability, observing whether energy flows converge to a minimum or remain bounded. Control measures are then developed based on these assessments to enhance stability [113]. This criterion evaluates both transient and steady-state stability, ensuring reliable operation under changing conditions. In essence, it provides a mathematical foundation for DC MG stability analysis and control development [76,79]. The state-space representation of DC/DC converters, leading to a matrix, allows for Lyapunov stability analysis to assess stability [50]. This analysis is also applicable to grid-tied synchronization, focusing on boundedness [51].
4. Stabilization Techniques for DC/DC Converters in DC MGs
Mitigating the detrimental effects of CPLs and PPLs requires effective system damping through modifications at the feeder side, source level (by adding a circuit in series or parallel), or load level. This can be achieved through hardware modifications or adjustments to the control loops. As outlined in [114], DC MGs with CPLs typically consist of three stages: source, filter, and load. The source stage includes power converters for voltage regulation, the filter stage employs filters to ensure CPL stability and shape voltage waveforms, and the load stage involves load converters connected to various loads. Stabilization methods for DG MG can be developed by addressing each stage individually [82,83].
From a communication perspective, source-side stabilization can be categorized into centralized approaches (including damping techniques, SMC, MPC, etc.) [115], decentralized mode (with droop control being one of the applicable controllers) [116], and distributed mode (involving communication topology between primary, secondary, and tertiary levels of control systems) [52]. The negative effects of CPLs and PPLs can reduce the stability and efficiency of the system and can be mitigated by using different stabilization techniques [53].
Stabilization techniques are reviewed based on their advantages, disadvantages, applications, determination methods, and limitations, and these are summarized in Table 2.
It provides a summary of these stabilization techniques along with the identified research gaps for each method. The investigated stabilization techniques include applying virtual impedance to cancel out the negative incremental impedance caused by CPLs and power imbalances caused by PPLs [111,117] employing model prediction to neutralize negative incremental impedance [15,76,87], utilizing feedback control to mitigate the effects of CPLs [6,62]. We also consider Brayton–Moser’s mixed potential theory, using passive and active damping techniques.
A summary of stability criteria, encompassing advantages, disadvantages, applications, and discussions, is presented in Table 3.
Table 2.
A summary of the stabilization techniques to cancel out negative incremental impedance characteristics for DC MGs.
Table 3.
Summary of stability analysis of DC/DC converters applications in DC MGs.
4.1. Virtual Impedance Construction for CPLs
Power oscillations are a prevalent issue in DC MGs because of the negative incremental impedance caused by CPLs [65]. Figure 9 represents a simplified schematized DC/DC converter with DC bus nominal voltage value symbolizes the CPL line inductance; meanwhile, is a source droop coefficient and r is a line resistor equivalent, is the equivalent load resistance, the CPL side equivalent capacitance is , the capacitor voltage is , the output current is , the power is , the CPL equivalent resistance is , and the CPL current is . The equivalent impedance could be written in Equations (18) and (19) as follows:
where
Figure 9.
Illustrates the equivalent circuit representing the DC/DC converter providing power to CPLs.
According to the Hurwitz stability criterion, the equivalent impedance Z(s) must not have a pole in the left half plane for the system to be asymptotically stable:
By solving Equations (18) and (19), the following Equation (20) can be derived and written as follows:
The stability limits of the system can be determined by formulating Equation (20), incorporating virtual impedance to eliminate the circuit’s inductance . Enhancing the damping of DC MGs with CPLs involves the application of virtual impedance to the output filter using a virtual impedance stabilization technique [83,84,89,118]. This addition results in system stability as the previously unstable pole induced by the CPLs relocates to a stable region.
4.2. Brayton–Moser’s Mixed Potential Theory
The voltage stability of DC MGs will play a pivotal role in future AC/DC hybrid distribution networks, making its maintenance essential for the network’s safety. Additionally, investigating the stability of DC MGs, which consist of various elements such as resistors, inductances, capacitors, and feed CPLs, under large disturbances can be carried out by applying Brayton–Moser’s mixed potential theory. Brayton and Moser have established three theorems for analyzing system stability characterized by nonlinear elements and subjected to large disturbances [123]. The stability criterion of the system under a large disturbance should be determined based on the theorems proven by Brayton and Moser, considering the characteristics of the network. This approach can help the system remain stable in the face of significant disturbances, reduce unnecessary switching between master and slave sources, and expedite the system’s return to a stable state [89,90,91].
4.3. Passive Damping Technique
A method for addressing the negative incremental impedance problems produced by CPLs is the passive damping technique, involving modifications to the input filter to enhance passive damping. This can be achieved by customizing the filter elements, accordingly, connecting resistances, capacitors, and/or inductors in parallel, series, or cascade with either the inductor or the capacitor in the input filter. However, adding passive components through this method increases the system’s price, weight, and size while also causing additional power losses, which are often undesired. Ideally, the input filter should be initially designed with sufficient damping to minimize power losses [93,96].
4.4. Active Damping Technique
Active damping produces the effect of parallel passive components by altering the control architecture of the system’s active components. Unlike passive components, the control laws are written in software, allowing for flexibility beyond the limitations of passive components. If the feeder consists entirely of passive components, the control structure of the load converter may need to be modified to implement active damping effectively. An auxiliary circuit can be added in parallel with the load subsystem to dampen the system [93,96]. The active damping method involves modifying the output impedance of the converters (), input impedance of the CPLs () and adding a shunt impedance (. The SWOT analysis of DC MGs based on DC/DC converters are summarized in Figure 10. Furthermore, DC/DC converters play an important part in DC MG applications. Their advantages include increased efficiency, reliable voltage regulation, and scalability. However, they confront several problems, including expensive costs, sophisticated control systems, and limited compatibility with AC loads. Technological breakthroughs and the global shift toward electrification open up new opportunities. Threats include legislative biases in favor of AC systems, market competition, and possible interoperability concerns. Effective strategic planning is required to capitalize on strengths and opportunities while addressing weaknesses and risks to ensure successful DC MG deployment.
Figure 10.
DC MGs SWOT analysis.
5. Discussion
The recent literature provides an overview of the global state of DC/DC converters in DC MGs and explores their potential future development. This paper conducts a SWOT analysis for DC MGs based on a review of research articles, standards, information from websites, and government policies. Figure 10 illustrates the SWOT analysis of DC MGs supplying CPLs and PPLs, presenting internal factors representing the strength and weakness of DC MGs versus external factors representing the opportunities and threats of DC MGs.
Control strategies are crucial to achieving the reliability, safety, and dynamic stability of DC/DC converters. However, while some proposed control strategies are suitable for large-signal stability, others are designed for small-signal stability and come with certain drawbacks, as outlined in Table 1. Given that the future network will be dominated by DERs, ongoing research on DC/DC converters will explore various topologies.
Controlled and regulated switching power converters exhibit behavior similar to CPLs. When subjected to small signal analysis, they demonstrate a negative incremental impedance, potentially reducing stability margins when dealing with PPLs or CPLs equipped with input filters. In response, the authors have evaluated several methods to stabilize the system and mitigate the adverse effects of CPLs and PPLs.
To ensure system stability, it is essential to assess these stabilization techniques using stability criteria and damping methods. Various methods for stability evaluation include applying stability criteria based on the Nyquist stability criterion to establish restricted regions for the minor loop’s polar plot. Checking that the minor loop gain adheres to the Nyquist stability criterion is crucial for ensuring the stability of DC/DC converters. Moreover, in the 1970s, Middlebrook and other authors proposed another stability criterion, which is summarized in Table 2 along with its extensions. Some stabilization techniques and stability criteria are suitable for small signal stability analysis, while others are suitable for large signal stability analysis, as detailed in Table 2 and Table 3. Additionally, a SWOT analysis for DC/DC converters in DC MGs is provided.
Input filters are necessary for switching converters to comply with conducted susceptibility requirements and reduce conducted electromagnetic interference. However, an undamped input filter can introduce instability into the converter’s regulator by introducing complex poles and right half plane (RHP) zeroes in resonant frequencies lower than the controller loop gain’s crossover frequency. When integrating an input filter into a converter, various transfer functions such as control-to-output and line-to-output transfer functions, as well as audio susceptibility, undergo changes. Therefore, it is crucial to account for the impact of the input filter during the design of the converter’s control system. The stability boundary is established through the following steps: evaluating the stability of the closed-loop converter by connecting the input filter output impedance to the converter’s input impedance, considering the ratio between the output impedance and input impedance as a minor loop gain. Traditional techniques, such as the Nyquist stability theorem and phase margin test, are then employed to assess the system’s stability.
6. Conclusions and Future Research Prospects
To mitigate the instability issues associated with CPLs and PPLs, this review article provides a comprehensive overview of control strategies, stabilization techniques, and stability criteria applicable to DC/DC converters in DC MGs. The negative incremental impedance characteristics of CPLs can lead to network instability, while PPLs may cause power imbalances and high-power consumption within a short time.
Various control strategies, such as MPC, BSC, SMC, PBC, disturbance estimation techniques, controllers employing AI, and nonlinear modeling approaches, can be employed to ensure system stability and enhance network reliability. A detailed summary of these control strategies is provided, highlighting their advantages, disadvantages, applications, and limitations.
Stabilization techniques, including the virtual impedance method, MPC, linear and nonlinear feedback techniques, robust stability framework, Brayton–Moser’s mixed potential theory, and passive and active damping techniques, are analyzed. A comparison is made based on their advantages, disadvantages, applications, determination methods, and limitations. It is emphasized that stabilization techniques must satisfy stability criteria requirements, as illustrated in Figure 8, with a focus on considering the minor loop gain.
Looking ahead, the exploration of control strategies and stabilization techniques for DC MGs supplying CPLs and PPLs is anticipated to further enhance system performance and stability. With government initiatives promoting the dominance of DERs in the future network, a combination of technologies, including power electronics, communication topology, fault monitoring, and proactive maintenance of MGs, will be crucial.
Ongoing efforts by organizations such as the European standards and IEEE standard committee, along with leading experts, are developing standards like IEEE 1547 [130], IEEE 946 [131], IEC SG4 [132,133]. IEEE DC home, and MIL-STD-1399 [134] for DC MGs, EN50155 [135] (voltage variations), EN61000-4-4 [136] (fast transients), and EN501121-3-2 [137] (EMI) [127]. However, standards related to protection and grounding schemes are yet to be established and should be considered in the future especially with the expansion of DC MGs from low-voltage levels to medium voltage.
Anticipating rapid growth, it is expected that medium-voltage DC (MVDC) distribution system applications, both grid-connected and autonomous, will require new HARDWARE configurations and different DC bus configurations to enhance network reliability and security. A recommendation is made for future safety standards compliance to be unified nationally and internationally based on the IEC 60950-1 [138] standard.
Funding
This research was funded by New Zealand Ministry of Business, Innovation and Enterprise (MBIE) SSIF ATF grant number AUT-R12216.01.
Acknowledgments
The authors would like to acknowledge the MBIE SSIF ATP project entitled ‘Architecture of the Future Low-Carbon, Resilient, Electrical Power System’ for their financial support.
Conflicts of Interest
The authors declare no conflict of interest.
References
- He, J.; Chen, Y.; Lin, J.; Chen, J.; Cheng, L.; Wang, Y. Review of Modeling, Modulation, and Control Strategies for the Dual-Active-Bridge DC/DC Converter. Energies 2023, 16, 6646. [Google Scholar] [CrossRef] [Scilit]
- Market.Us. Power Electronic Market Size to Surpass USD 94.21 Bn Revenue by 2032. Available online: https://www.globenewswire.com/en/news-release/2023/04/13/2646669/0/en/Power-Electronic-Market-Size-to-Surpass-USD-94-21-Bn-Revenue-by-2032.html (accessed on 30 September 2023).
- Lucas Nülle—Controlling Energy from Microgrids. Available online: https://www.lucas-nuelle.us/2808n1094 (accessed on 14 January 2024).
- Forouzesh, M.; Siwakoti, Y.P.; Gorji, S.A.; Blaabjerg, F.; Lehman, B. Step-Up DC-DC converters: A comprehensive review of voltage-boosting techniques, topologies, and applications. IEEE Trans. Power Electron. 2017, 32, 9143–9178. [Google Scholar] [CrossRef] [Scilit]
- Strzelecki, R.; Benysek, G. Power Electronics in Smart Electrical Energy Networks; Springer: Berlin/Heidelberg, Germany, 2008; Volume 34. [Google Scholar] [CrossRef] [Scilit]
- Guney, M.S.; Tepe, Y. Classification and assessment of energy storage systems. Renew. Sustain. Energy Rev. 2017, 75, 1187–1197. [Google Scholar] [CrossRef] [Scilit]
- Arrua, S. DC Bus Stabilization and Dynamic Performance Improvement of a Multi-Converter System. Ph.D. Thesis, University of South Carolina, Columbia, SC, USA, 2019. [Google Scholar]
- Elsayed, A.T.; Youssef, T.A.; Mohammed, O.A. Modeling and Control of a Low-Speed Flywheel Driving System for Pulsed-Load Mitigation in DC Distribution Networks. IEEE Trans. Ind. Appl. 2016, 52, 3378–3387. [Google Scholar] [CrossRef] [Scilit]
- Neely, J.; Pekarek, S.; DeCarlo, R.; Vaks, N. Real-time hybrid model predictive control of a boost converter with constant power load. In Proceedings of the 2010 Twenty-Fifth Annual IEEE Applied Power Electronics Conference and Exposition (APEC), Palm Springs, CA, USA, 21–25 February 2010; pp. 480–490. [Google Scholar] [CrossRef] [Scilit]
- Feng, X.; Shekhar, A.; Yang, F.; Hebner, R.E.; Bauer, P. Comparison of Hierarchical Control and Distributed Control for Microgrid. Electr. Power Compon. Syst. 2017, 45, 1043–1056. [Google Scholar] [CrossRef] [Scilit]
- Jackson, R.; Zulkifli, S.A.; Benbouzid, M.; Salimin, S.; Khan, M.H.; Elhassan, G.; Pathan, E. A comprehensive motivation of multilayer control levels for microgrids: Synchronization, voltage and frequency restoration perspective. Appl. Sci. 2020, 10, 8355. [Google Scholar] [CrossRef] [Scilit]
- Al-Tameemi, Z.H.A.; Lie, T.T.; Foo, G.; Blaabjerg, F. Control strategies of DC microgrids cluster: A comprehensive review. Energies 2021, 14, 7569. [Google Scholar] [CrossRef] [Scilit]
- Meng, L.; Luna, A.; Díaz, E.R.; Sun, B.; Dragicevic, T.; Savaghebi, M.; Vasquez, J.C.; Guerrero, J.M.; Graells, M.; Andrade, F. Flexible System Integration and Advanced Hierarchical Control Architectures in the Microgrid Research Laboratory of Aalborg University. IEEE Trans. Ind. Appl. 2016, 52, 1736–1749. [Google Scholar] [CrossRef] [Scilit]
- Guerrero, J.M.; Vasquez, J.C.; Matas, J.; De Vicuña, L.G.; Castilla, M. Hierarchical control of droop-controlled AC and DC microgrids—A general approach toward standardization. IEEE Trans. Ind. Electron. 2011, 58, 158–172. [Google Scholar] [CrossRef] [Scilit]
- Litrán, S.P.; Durán, E.; Semião, J.; Díaz-Martín, C. Multiple-Output DC-DC Converters: Applications and Solutions. Electronics 2022, 11, 1258. [Google Scholar] [CrossRef] [Scilit]
- Igliński, B.; Skrzatek, M.; Kujawski, W.; Cichosz, M.; Buczkowski, R. SWOT Analysis of Renewable Energy Sector in Mazowieckie Voivodeship (Poland): Current Progress, Prospects and Policy Implications; Springer: Dordrecht, The Netherlands, 2022; Volume 24, No. 1. [Google Scholar] [CrossRef] [Scilit]
- Dhananjaya, M.; Pattnaik, S. Design and implementation of a SIMO DC–DC converter. IET Power Electron. 2019, 12, 1868–1879. [Google Scholar] [CrossRef] [Scilit]
- Nahata, P.; La Bella, A.; Scattolini, R.; Ferrari-Trecate, G. Hierarchical Control in Islanded DC Microgrids with Flexible Structures. IEEE Trans. Control Syst. Technol. 2021, 29, 2379–2392. [Google Scholar] [CrossRef] [Scilit]
- Behjati, H.; Davoudi, A. A multiple-input multiple-output DC-DC converter. IEEE Trans. Ind. Appl. 2013, 49, 1464–1479. [Google Scholar] [CrossRef] [Scilit]
- Onar, O.C.; Khaligh, A. A novel integrated magnetic structure based DC/DC converter for hybrid battery/ultracapacitor energy storage systems. IEEE Trans. Smart Grid 2012, 3, 296–307. [Google Scholar] [CrossRef] [Scilit]
- Braitor, A. Advanced Hierarchical Control and Stability Analysis of DC Microgrids; Springer: Berlin/Heidelberg, Germany, 2020. [Google Scholar]
- Aranda, E.D.; Litran, S.P.; Prieto, M.B.F. Combination of interleaved single-input multiple-output DC-DC converters. CSEE J. Power Energy Syst. 2022, 8, 132–142. [Google Scholar] [CrossRef] [Scilit]
- Ali, S.; Zheng, Z.; Aillerie, M.; Sawicki, J.P.; Péra, M.C.; Hissel, D. A review of dc microgrid energy management systems dedicated to residential applications. Energies 2021, 14, 4308. [Google Scholar] [CrossRef] [Scilit]
- Moussa, S.; Ghorbal, M.J.B.; Slama-Belkhodja, I. Bus voltage level choice for standalone residential DC nanogrid. Sustain. Cities Soc. 2019, 46, 101431. [Google Scholar] [CrossRef] [Scilit]
- Dragičević, T.; Lu, X.; Vasquez, J.C.; Guerrero, J.M. DC Microgrids—Part II: A Review of Power Architectures, Applications, and Standardization Issues. IEEE Trans. Power Electron. 2016, 31, 3528–3549. [Google Scholar] [CrossRef] [Scilit]
- Xu, Q.; Yan, Y.; Zhang, C.; Dragicevic, T.; Blaabjerg, F. An Offset-Free Composite Model Predictive Control Strategy for DC/DC Buck Converter Feeding Constant Power Loads. IEEE Trans. Power Electron. 2020, 35, 5331–5342. [Google Scholar] [CrossRef] [Scilit]
- Xu, Q.; Vafamand, N.; Chen, L.; Dragicevic, T.; Xie, L.; Blaabjerg, F. Review on Advanced Control Technologies for Bidirectional DC/DC Converters in DC Microgrids. IEEE J. Emerg. Sel. Top. Power Electron. 2021, 9, 1205–1221. [Google Scholar] [CrossRef] [Scilit]
- Bento, F.; Cardoso, A.J.M. Model-Free Predictive Control of Multilevel DC-DC Converters for Energy Storage Applications. In Proceedings of the IECON 2022—48th Annual Conference of the IEEE Industrial Electronics Society, Brussels, Belgium, 17–20 October 2022; pp. 1–5. [Google Scholar] [CrossRef] [Scilit]
- Kumar, D.; Kumar, C. Model Predictive Control of Bi-directional dc-dc Converter for Battery Charger Application. In Proceedings of the 2022 22nd National Power Systems Conference (NPSC), New Delhi, India, 17–19 December 2022; pp. 65–70. [Google Scholar] [CrossRef] [Scilit]
- Zhou, J.; Hassan, M.A.; Zhang, J.; Hou, M.; Wu, S.; Xing, G.; Chi, S. Stabilization of constant power loads in dc microgrid systems using an adaptive continuous control set model predictive control. Symmetry 2021, 13, 1112. [Google Scholar] [CrossRef] [Scilit]
- Wang, L. Model Predictive Control: Design and implementation using MATLAB (T-3). In Proceedings of the 2009 American Control Conference, St. Louis, MO, USA, 10–12 June 2009. [Google Scholar] [CrossRef] [Scilit]
- Truong, Q. Continuous-Time Model Predictive Control. Master’s Thesis, RMIT University, Melbourne, Australia, 2007; pp. 1–162. [Google Scholar]
- Pannocchia, G. Handbook of Model Predictive Control [Bookshelf]. IEEE Control Syst. Mag. 2022, 40, 96–99. [Google Scholar] [CrossRef] [Scilit]
- Raković, S.V. Model Predictive Control: Classical, Robust, and Stochastic [Bookshelf]. IEEE Control Syst. Mag. 2016, 36, 102–105. [Google Scholar] [CrossRef]
- Khan, M.S.; Ahmad, I.; Armaghan, H.; Ali, N. Backstepping sliding mode control of FC-UC based hybrid electric vehicle. IEEE Access 2018, 6, 77202–77211. [Google Scholar] [CrossRef] [Scilit]
- Beccuti, A.G.; Mariéthoz, S.; Cliquennois, S.; Wang, S.; Morari, M. Explicit model predictive control of DC-DC switched-mode power supplies with extended kalman filtering. IEEE Trans. Ind. Electron. 2009, 56, 1864–1874. [Google Scholar] [CrossRef] [Scilit]
- Kumar, J.; Agarwal, A.; Agarwal, V. A review on overall control of DC microgrids. J. Energy Storage 2019, 21, 113–138. [Google Scholar] [CrossRef] [Scilit]
- Wu, J.; Lu, Y. Adaptive Backstepping Sliding Mode Control for Boost Converter With Constant Power Load. IEEE Access 2019, 7, 50797–50807. [Google Scholar] [CrossRef] [Scilit]
- Zhang, M.; Li, Y.; Liu, F.; Luo, L.; Cao, Y.; Shahidehpour, M. Voltage stability analysis and sliding-mode control method for rectifier in DC systems with constant power loads. IEEE J. Emerg. Sel. Top. Power Electron. 2017, 5, 1621–1630. [Google Scholar] [CrossRef] [Scilit]
- Martinez-Treviño, B.A.; El Aroudi, A.; Vidal-Idiarte, E.; Cid-Pastor, A.; Martinez-Salamero, L. Sliding-mode control of a boost converter under constant power loading conditions. IET Power Electron. 2019, 12, 521–529. [Google Scholar] [CrossRef] [Scilit]
- Singh, S.; Kumar, V.; Fulwani, D. Mitigation of destabilising effect of CPLs in island DC micro-grid using non-linear control. IET Power Electron. 2017, 10, 387–397. [Google Scholar] [CrossRef] [Scilit]
- Amrr, S.M.; Ahmad, J.; Waheed, S.A.; Sarwar, A.; Saidi, A.S.; Nabi, M. Finite-Time Adaptive Sliding Mode Control of a Power Converter Under Multiple Uncertainties. Front. Energy Res. 2022, 10, 901606. [Google Scholar] [CrossRef] [Scilit]
- Su, L.; Gupta, V.; Antsaklis, P. Feedback Passivation of Linear Systems with Fixed-Structure Controllers. IEEE Control Syst. Lett. 2020, 4, 498–503. [Google Scholar] [CrossRef]
- Fujimoto, K.; Sakata, N.; Maruta, I.; Ferguson, J. A Passivity Based Sliding Mode Controller for Simple Port-Hamiltonian Systems. IEEE Control Syst. Lett. 2021, 5, 839–844. [Google Scholar] [CrossRef] [Scilit]
- Kwasinski, A.; Krein, P.T. Passivity-based control of buck converters with constant-power loads. In Proceedings of the 2007 IEEE Power Electronics Specialists Conference, Orlando, FL, USA, 17–21 June 2007; pp. 259–265. [Google Scholar] [CrossRef] [Scilit]
- Mehta, A.; Naik, B. Sliding Mode Controllers for Power Electronic Converters; Springer: Berlin/Heidelberg, Germany, 2019; Volume 534. [Google Scholar] [CrossRef] [Scilit]
- Alam, F.; Haider Zaidi, S.S.; Rehmat, A.; Mutarraf, M.U.; Nasir, M.; Guerrero, J.M. Robust Hierarchical Control Design for the Power Sharing in Hybrid Shipboard Microgrids. Inventions 2022, 8, 7. [Google Scholar] [CrossRef] [Scilit]
- Tan, S.C.; Lai, Y.M.; Tse, C.K. Implementation of pulse-width-modulation based sliding mode controller for boost converters. IEEE Power Electron. Lett. 2005, 3, 130–135. [Google Scholar] [CrossRef]
- Zeng, J.; Zhang, Z.; Qiao, W. An interconnection and damping assignment passivity-based controller for a DC-DC boost converter with a constant power load. IEEE Trans. Ind. Appl. 2014, 50, 2314–2322. [Google Scholar] [CrossRef] [Scilit]
- Kondratiev, I.; Dougal, R. Synergetic control strategies for shipboard DC power distribution systems. In Proceedings of the 2007 American Control Conference, New York, NY, USA, 9–13 July 2007; pp. 4744–4749. [Google Scholar] [CrossRef] [Scilit]
- Kondratiev, I.; Dougal, R.; Santi, E.; Veselov, G. Synergetic control for DC-DC buck converters with constant power load. In Proceedings of the 2004 IEEE 35th Annual Power Electronics Specialists Conference, Aachen, Germany, 20–25 June 2004; Volume 5, pp. 3758–3764. [Google Scholar] [CrossRef] [Scilit]
- Khan, H.S.; Mohamed, I.S.; Kauhaniemi, K.; Liu, L. Artificial Neural Network-Based Voltage Control of DC/DC Converter for DC Microgrid Applications. In Proceedings of the 2021 6th IEEE Workshop on the Electronic Grid (eGRID), New Orleans, LA, USA, 8–10 November 2021; pp. 1–6. [Google Scholar] [CrossRef] [Scilit]
- Koduru, S.S.; MacHina, V.S.P.; Madichetty, S. Real-Time Implementation of Deep Learning Technique in Microcontroller-Based DC-DC Boost Converter—A Design Approach. In Proceedings of the 2022 IEEE Delhi Section Conference (DELCON), New Delhi, India, 11–13 February 2022; pp. 1–6. [Google Scholar] [CrossRef] [Scilit]
- Wang, Y.; Nguyen, T.L.; Syed, M.H.; Xu, Y.; Guillo-Sansano, E.; Nguyen, V.-H.; Burt, G.M.; Tran, Q.-T.; Caire, R. A Distributed Control Scheme of Microgrids in Energy Internet Paradigm and Its Multisite Implementation. IEEE Trans. Ind. Inform. 2021, 17, 1141–1153. [Google Scholar] [CrossRef] [Scilit]
- Farsizadeh, H.; Gheisarnejad, M.; Mosayebi, M.; Rafiei, M.; Khooban, M.H. An Intelligent and Fast Controller for DC/DC Converter Feeding CPL in a DC Microgrid. IEEE Trans. Circuits Syst. II Express Briefs 2020, 67, 1104–1108. [Google Scholar] [CrossRef] [Scilit]
- Hussaini, H.; Member, S.; Yang, T.; Member, S.; Bai, G.; Member, S. Artificial Intelligence-Based Hierarchical Control Design for Current Sharing and Voltage Restoration in DC Microgrid of the More Electric Aircraft. IEEE Trans. Transp. Electrif. 2023; early access. [CrossRef] [Scilit]
- Sorouri, H.; Sedighizadeh, M.; Oshnoei, A.; Khezri, R. International Journal of Electrical Power and Energy Systems An intelligent adaptive control of DC—DC power buck converters. Int. J. Electr. Power Energy Syst. 2022, 141, 108099. [Google Scholar] [CrossRef] [Scilit]
- Hassan, M.A.; Su, C.-L.; Pou, J.; Sulligoi, G.; Almakhles, D.; Bosich, D.; Guerrero, J.M. DC Shipboard Microgrids with Constant Power Loads: A Review of Advanced Nonlinear Control Strategies and Stabilization Techniques. IEEE Trans. Smart Grid 2022, 13, 3422–3438. [Google Scholar] [CrossRef] [Scilit]
- Zhang, Y.; Qu, X.; Tang, M.; Yao, R.; Chen, W. Design of Nonlinear Droop Control in DC Microgrid for Desired Voltage Regulation and Current Sharing Accuracy. IEEE J. Emerg. Sel. Top. Circuits Syst. 2021, 11, 168–175. [Google Scholar] [CrossRef] [Scilit]
- Lin, Y.; Member, S.; Xiao, W.; Member, S. Novel Piecewise Linear Formation of Droop Strategy for DC Microgrid. IEEE Trans. Smart Grid 2019, 10, 6747–6755. [Google Scholar] [CrossRef] [Scilit]
- Chen, F.; Burgos, R.; Boroyevich, D.; Vasquez, J.C.; Guerrero, J.M. Investigation of Nonlinear Droop Control in DC Power Distribution Systems: Load Sharing, Voltage Regulation, Efficiency, and Stability. IEEE Trans. Power Electron. 2019, 34, 9404–9421. [Google Scholar] [CrossRef] [Scilit]
- Shah, S.U.; Charan, D.C.S.; Rajpathak, B. Application of Piecewise-smooth System Theory in Droop Control. In Proceedings of the 2021 9th IEEE International Conference on Power Systems (ICPS), Kharagpur, India, 16–18 December 2021. [Google Scholar] [CrossRef] [Scilit]
- Riccobono, A.; Santi, E. Comprehensive review of stability criteria for DC power distribution systems. IEEE Trans. Ind. Appl. 2014, 50, 3525–3535. [Google Scholar] [CrossRef] [Scilit]
- Xu, Q.; Zhang, C.; Wen, C.; Wang, P. A Novel Composite Nonlinear Controller for Stabilization of Constant Power Load in DC Microgrid. IEEE Trans. Smart Grid 2017, 10, 752–761. [Google Scholar] [CrossRef] [Scilit]
- Wang, J.; Luo, W.; Liu, J.; Wu, L. Adaptive Type-2 FNN-Based Dynamic Sliding Mode Control of DC-DC Boost Converters. IEEE Trans. Syst. Man Cybern. Syst. 2021, 51, 2246–2257. [Google Scholar] [CrossRef] [Scilit]
- Mestriner, D.; Rosini, A.; Xhani, I.; Bonfiglio, A.; Procopio, R. Primary Voltage and Frequency Regulation in Inverter Based Islanded Microgrids through a Model Predictive Control Approach. Energies 2022, 15, 5077. [Google Scholar] [CrossRef] [Scilit]
- Simiyu, P.; Xin, A.; Bitew, G.T.; Shahzad, M.; Kunyu, W.; Kamunyu, P.M. Small-signal stability analysis for the multi-terminal VSC MVDC distribution network; a review. J. Eng. 2019, 2019, 1068–1075. [Google Scholar] [CrossRef] [Scilit]
- Karppanen, M.; Suntio, T. Minor-loop gain as a source of information on robust stability and transient performance in an interconnected system. EPE J. 2009, 19, 28–35. [Google Scholar] [CrossRef] [Scilit]
- Ma, D.; Ki, W.H.; Tsui, C.Y. A pseudo-CCM/DCM SIMO switching converter with freewheel switching. IEEE J. Solid-State Circuits 2003, 38, 1007–1014. [Google Scholar] [CrossRef] [Scilit]
- Liao, Y.; Wang, X. Impedance-Based Stability Analysis for Interconnected Converter Systems with Open-Loop RHP Poles. IEEE Trans. Power Electron. 2020, 35, 4388–4397. [Google Scholar] [CrossRef] [Scilit]
- Kuhn, M.R.; Ji, Y.; Schrder, D. Stability studies of critical DC power system component for more electric aircraft using μ sensitivity. In Proceedings of the 2007 Mediterranean Conference on Control & Automation, Athens, Greece, 27–29 June 2007. [Google Scholar] [CrossRef] [Scilit]
- Alam, M.Z.; Roy, T.K.; Ghosh, S.K.; Mohammad, N.; Paul, L.C. Output Voltage Stability of a DC-DC Buck Converter via an Improved Backstepping Method. In Proceedings of the 2023 International Conference on Electrical, Computer and Communication Engineering (ECCE), Chittagong, Bangladesh, 23–25 February 2023; pp. 1–5. [Google Scholar] [CrossRef] [Scilit]
- Rivetta, C.; Williamson, G.A. Large-Signal Analysis of a DC-DC Buck Power Converter Operating with Constant Power Load. In Proceedings of the 29th Annual Conference of the IEEE Industrial Electronics Society (IECON’03), Roanoke, VA, USA, 2–6 November 2003; Volume 1, pp. 732–737. [Google Scholar] [CrossRef] [Scilit]
- Wang, X.; Yao, R.; Rao, F. Three-step impedance criterion for small-signal stability analysis in two-stage DC distributed power systems. IEEE Power Electron. Lett. 2003, 1, 83–87. [Google Scholar] [CrossRef] [Scilit]
- Grillo, S.; Musolino, V.; Sulligoi, G.; Tironi, E. Stability enhancement in DC distribution systems with constant power controlled converters. In Proceedings of the 2012 IEEE 15th International Conference on Harmonics and Quality of Power, Hong Kong, China, 17–20 June 2012; pp. 848–854. [Google Scholar] [CrossRef] [Scilit]
- Martirosyan, A.V.; Martirosyan, K.V.; Chernyshev, A.B. Investigation of Popov’s Lines’ Limiting Position to Ensure the Process Control Systems’ Absolute Stability. In Proceedings of the 2023 XXVI International Conference on Soft Computing and Measurements (SCM), Saint Petersburg, Russia, 24–26 May 2023; pp. 69–72. [Google Scholar] [CrossRef] [Scilit]
- Chettibi, N.; Mellit, A.; Sulligoi, G.; Pavan, A.M. Adaptive Neural Network-Based Control of a Hybrid AC/DC Microgrid. IEEE Trans. Smart Grid 2018, 9, 1667–1679. [Google Scholar] [CrossRef] [Scilit]
- Sabanovic, A.; Sabanovic, N.; Music, O. Sliding Mode Control of Dc-Ac Converters. In Proceedings of the 1986 17th Annual IEEE Power Electronics Specialists Conference, Vancouver, BC, Canada, 23–27 June 1986; pp. 560–566. [Google Scholar] [CrossRef] [Scilit]
- Zeng, X.; Li, Z.; Wu, Y.; Gao, W.; Zhang, J.; Ren, M.; Zhang, B. Dynamic Stability Analysis based on State-space Model and Lyapunov ’ s Stability Criterion for SiC-MOS and Si-IGBT Switching. In Proceedings of the 2018 IEEE 30th International Symposium on Power Semiconductor Devices and ICs (ISPSD), Chicago, IL, USA, 13–17 May 2018; pp. 268–271. [Google Scholar] [CrossRef] [Scilit]
- Wei, Y. Lyapunov Stability Theory for Nonlinear Nabla Fractional Order Systems. IEEE Trans. Circuits Syst. II Express Briefs 2021, 68, 3246–3250. [Google Scholar] [CrossRef] [Scilit]
- Long, F.; Pang, L.; Zhang, C.; He, Y. A novel augmented Lyapunov functional for the stability analysis of delayed neural networks. In Proceedings of the 2018 37th Chinese Control Conference (CCC), Wuhan, China, 25–27 July 2018; pp. 873–878. [Google Scholar]
- Ansari, S.; Zhang, J.; Singh, R.E. A review of stabilization methods for DCMG with CPL, the role of bandwidth limits and droop control. Prot. Control Mod. Power Syst. 2022, 7, 2. [Google Scholar] [CrossRef] [Scilit]
- Lu, X.; Sun, K.; Guerrero, J.M.; Vasquez, J.C.; Huang, L.; Wang, J. Stability Enhancement Based on Virtual Impedance for DC Microgrids with Constant Power Loads. IEEE Trans. Smart Grid 2015, 6, 2770–2783. [Google Scholar] [CrossRef] [Scilit]
- Liu, S.; Su, P.; Zhang, L. A virtual negative inductor stabilizing strategy for DC microgrid with constant power loads. IEEE Access 2018, 6, 59728–59741. [Google Scholar] [CrossRef] [Scilit]
- Zhao, Q.; Tao, F.; Hu, Y.; Lee, F.C. Active-clamp DC/DC converters using magnetic switches. In Proceedings of the APEC 2001. Sixteenth Annual IEEE Applied Power Electronics Conference and Exposition, Anaheim, CA, USA, 4–8 March 2001; Volume 2, pp. 946–952. [Google Scholar] [CrossRef] [Scilit]
- Rouzbehi, K.; Miranian, A.; Escaño, J.M.; Rakhshani, E.; Shariati, N.; Pouresmaeil, E. A Data-Driven Based Voltage Control Strategy for DC-DC Converters: Application to DC Microgrid. Electronics 2019, 8, 493. [Google Scholar] [CrossRef] [Scilit]
- Yousefizadeh, S.; Bendtsen, J.D.; Vafamand, N.; Khooban, M.H.; Dragicevic, T.; Blaabjerg, F. EKF-Based Predictive Stabilization of Shipboard DC Microgrids with Uncertain Time-Varying Load. IEEE J. Emerg. Sel. Top. Power Electron. 2019, 7, 901–909. [Google Scholar] [CrossRef] [Scilit]
- Ding, N.; Prasad, K.; Lie, T.T.; Cui, J. State of charge estimation of a composite lithium-based battery model based on an improved extended Kalman filter algorithm. Inventions 2019, 4, 66. [Google Scholar] [CrossRef] [Scilit]
- Laib, K.; Watson, J.; Ojo, Y.; Lestas, I. Decentralized Stability Conditions in DC Microgrids. In Proceedings of the 2021 60th IEEE Conference on Decision and Control (CDC), Austin, TX, USA, 14–17 December 2021; pp. 5659–5664. [Google Scholar] [CrossRef] [Scilit]
- Jeltsema, D.; Scherpen, J.M.A. On Brayton and Moser’s Missing Stability Theorem. IEEE Trans. Circuits Syst. II Express Briefs 2005, 52, 550–552. [Google Scholar] [CrossRef] [Scilit]
- Zekun, L.; Wei, P.; Li, K. Large-disturbance stability analysis of DC microgrid with constant power load and its transient voltage stability control strategy. In Proceedings of the 2018 China International Conference on Electricity Distribution (CICED), Tianjin, China, 17–19 September 2018; pp. 1686–1690. [Google Scholar] [CrossRef] [Scilit]
- Prabhakaran, P.; Goyal, Y.; Agarwal, V. Novel Nonlinear Droop Control Techniques to Overcome the Load Sharing and Voltage Regulation Issues in DC Microgrid. IEEE Trans. Power Electron. 2018, 33, 4477–4487. [Google Scholar] [CrossRef] [Scilit]
- Wu, M.; Lu, D.D.C. Active stabilization methods of electric power systems with constant power loads: A review. J. Mod. Power Syst. Clean Energy 2014, 2, 233–243. [Google Scholar] [CrossRef] [Scilit]
- Snehal, N.; Pooja, W.; Sonam, K. Model Predictive Control for DC-DC Buck Converter using Enumeration. In Proceedings of the 2020 52nd North American Power Symposium (NAPS), Tempe, AZ, USA, 11–13 April 2021; pp. 1–6. [Google Scholar] [CrossRef] [Scilit]
- Du, W.; Zhang, J.; Zhang, Y.; Qian, Z. Stability criterion for cascaded system with constant power load. IEEE Trans. Power Electron. 2013, 28, 1843–1851. [Google Scholar] [CrossRef] [Scilit]
- Singh, S.; Gautam, A.R.; Fulwani, D. Constant power loads and their effects in DC distributed power systems: A review. Renew. Sustain. Energy Rev. 2017, 72, 407–421. [Google Scholar] [CrossRef] [Scilit]
- Vesti, S.; Suntio, T.; Oliver, J.A.; Prieto, R.; Cobos, J.A. Impedance-based stability and transient-performance assessment applying maximum peak criteria. IEEE Trans. Power Electron. 2013, 28, 2099–2104. [Google Scholar] [CrossRef] [Scilit]
- Pires, V.F.; Romero-Cadaval, E.; Vinnikov, D.; Roasto, I.; Martins, J.F. Power converter interfaces for electrochemical energy storage systems—A review. Energy Convers. Manag. 2014, 86, 453–475. [Google Scholar] [CrossRef] [Scilit]
- Pan, F.; Chen, J.; Xiao, C.; Zhou, Z. Model predictive control of bidirectional DC/DC converters for hydrogen fuel cell vehicles. In Proceedings of the 2020 Chinese Automation Congress (CAC), Shanghai, China, 6–8 November 2020; pp. 5778–5782. [Google Scholar] [CrossRef] [Scilit]
- Katir, H.; Abouloifa, A.; Noussi, K.; Lachkar, I.; El Aroudi, A.; Aourir, M.; El Otmani, F.; Giri, F. Fault Tolerant Backstepping Control for Double-Stage Grid-Connected Photovoltaic Systems Using Cascaded H-Bridge Multilevel Inverters. IEEE Control Syst. Lett. 2022, 6, 1406–1411. [Google Scholar] [CrossRef] [Scilit]
- Hossain, E.; Perez, R.; Nasiri, A.; Padmanaban, S. A Comprehensive Review on Constant Power Loads Compensation Techniques. IEEE Access 2018, 6, 33285–33305. [Google Scholar] [CrossRef] [Scilit]
- Alharbi, K.S.; McCann, R.A. Non-Overparametrized Adaptive Backstepping Control of PWM DC-DC Non-Inverting Buck-Boost Power Converter. In Proceedings of the 2019 IEEE Green Technologies Conference (GreenTech), Lafayette, LA, USA, 3–6 April 2019; pp. 1–5. [Google Scholar] [CrossRef] [Scilit]
- Sudhoff, S.D.; Glover, S.F.; Lamm, P.; Schmucker, D.; Delisle, D. Admittance space stability analysis of power electronic systems. IEEE Trans. Aerosp. Electron. Syst. 2000, 36, 965–973. [Google Scholar] [CrossRef] [Scilit]
- Xu, J.-X. Sliding mode control in engineering. Automatica 2003, 39, 951–954. [Google Scholar] [CrossRef] [Scilit]
- Ahmadzadeh, S.; Markadeh, G.A.; Abiadi, N. Adaptive Sliding Mode Control of Step-Up/Step-Down Z-Source DC-DC Converter. In Proceedings of the 2019 27th Iranian Conference on Electrical Engineering (ICEE), Yazd, Iran, 30 April–2 May 2019; pp. 841–845. [Google Scholar]
- Liu, H.; Guo, W.; Cheng, D.; Wang, Y.; Wang, M. Stability and Bifurcation Analysis of DC Microgrid with Multiple Droop Control Sources and Loads. IEEE Trans. Power Electron. 2021, 36, 2361–2372. [Google Scholar] [CrossRef] [Scilit]
- Erokhina, E.; Kiselev, M.; Kryukov, K.; Tserkovsky, Y.; Lepanov, M. Analysis of processes in the boost DC-DC converter with sliding mode control. In Proceedings of the 2021 3rd International Youth Conference on Radio Electronics, Electrical and Power Engineering (REEPE), Moscow, Russia, 11–13 March 2021; pp. 3–8. [Google Scholar] [CrossRef] [Scilit]
- Murakawa, Y.; Hikihara, T. Regulation of Parallel Connected Boost and Buck Converters by Passivity-Based Control. In Proceedings of the 2020 IEEE Workshop on Wide Bandgap Power Devices and Applications in Asia (WiPDA Asia), Suita, Japan, 23–25 September 2020; pp. 14–18. [Google Scholar] [CrossRef] [Scilit]
- Riccobono, A.; Santi, E. A novel Passivity-Based Stability Criterion (PBSC) for switching converter DC distribution systems. In Proceedings of the 2012 Twenty-Seventh Annual IEEE Applied Power Electronics Conference and Exposition (APEC), Orlando, FL, USA, 5–9 February 2012; pp. 2560–2567. [Google Scholar] [CrossRef] [Scilit]
- Eguchi, K.; Shibata, A.; Asadi, F.; Ishibashi, T.; Harada, Y.; Oota, I. Design of an LED Sink Driver Using a Switched-Inductor and Switched-Capacitor Buck-Boost Converter with High Voltage Gains. In Proceedings of the 2020 2nd International Conference on Smart Power & Internet Energy Systems (SPIES), Bangkok, Thailand, 15–18 September 2020; pp. 33–38. [Google Scholar]
- Sanchez, S.; Molinas, M. Assessment of a stability analysis tool for constant power loads in DC-grids. In Proceedings of the 2012 15th International Power Electronics and Motion Control Conference (EPE/PEMC), Novi Sad, Serbia, 4–6 September 2012; pp. 2–6. [Google Scholar] [CrossRef] [Scilit]
- Li, Y.; Wei, Y.; Chen, Y.; Wang, Y. A Universal Framework of the Generalized Kalman-Yakubovich-Popov Lemma for Singular Fractional-Order Systems. IEEE Trans. Syst. Man Cybern. Syst. 2021, 51, 5209–5217. [Google Scholar] [CrossRef] [Scilit]
- Shahid, I.U.R.; Kazmi, S.N.; Tahir, S. Study of Performance Enhancement Using Soft Sliding Mode Controller and Synergetic Controller for Multilevel Grid Tied Inverter. In Proceedings of the 2021 16th International Conference on Emerging Technologies (ICET), Islamabad, Pakistan, 22–23 December 2021; pp. 1–6. [Google Scholar] [CrossRef] [Scilit]
- Wu, T.F.; Chang, C.H.; Lin, L.C.; Yu, G.R.; Chang, Y.R. DC-bus voltage control with a three-phase bidirectional inverter for DC distribution systems. IEEE Trans. Power Electron. 2013, 28, 1890–1899. [Google Scholar] [CrossRef] [Scilit]
- Salomonsson, D.; Soder, L.; Sannino, A. An adaptive control system for a DC microgrid for data centers. IEEE Trans. Ind. Appl. 2008, 44, 1910–1917. [Google Scholar] [CrossRef] [Scilit]
- Saberi, H.; Mehraeen, S.; Rezvani, M.M. Intelligent Operation of Small-Scale Interconnected DC Grids via Measurement Redundancy. IEEE Trans. Ind. Electron. 2019, 66, 9086–9096. [Google Scholar] [CrossRef] [Scilit]
- Pang, S.; Nahid-Mobarakeh, B.; Pierfederici, S.; Phattanasak, M.; Huangfu, Y.; Luo, G.; Gao, F. Interconnection and Damping Assignment Passivity-Based Control Applied to On-Board DC-DC Power Converter System Supplying Constant Power Load. IEEE Trans. Ind. Appl. 2019, 55, 6476–6485. [Google Scholar] [CrossRef] [Scilit]
- Hussain, M.N.; Mishra, R.; Agarwal, V. A Frequency-Dependent Virtual Impedance for Voltage-Regulating Converters Feeding Constant Power Loads in a DC Microgrid. IEEE Trans. Ind. Appl. 2018, 54, 5630–5639. [Google Scholar] [CrossRef] [Scilit]
- Liu, J.; Zhang, W.; Rizzoni, G. Robust Stability Analysis of DC Microgrids with Constant Power Loads. IEEE Trans. Power Syst. 2018, 33, 851–860. [Google Scholar] [CrossRef] [Scilit]
- Chang, F.; Cui, X.; Wang, M.; Su, W.; Huang, A.Q. Large-Signal Stability Criteria in DC Power Grids with Distributed-Controlled Converters and Constant Power Loads. IEEE Trans. Smart Grid 2020, 11, 5273–5287. [Google Scholar] [CrossRef] [Scilit]
- Thai, S.; Roos, C.; Biannic, J.M. Probabilistic μ-analysis for stability and H∞ performance verification. In Proceedings of the 2019 American Control Conference (ACC), Philadelphia, PA, USA, 10–12 July 2019; pp. 3099–3104. [Google Scholar]
- Karimipour, D.; Salmasi, F.R. Stability Analysis of AC Microgrids With Constant Power Loads Based on Popov’s Absolute Stability Criterion. IEEE Trans. Circuits Syst. II Express Briefs 2015, 62, 696–700. [Google Scholar] [CrossRef] [Scilit]
- Marx, D.; Magne, P.; Nahid-Mobarakeh, B.; Pierfederici, S.; Davat, B. Large signal stability analysis tools in DC power systems with constant power loads and variable power loads-A review. IEEE Trans. Power Electron. 2012, 27, 1773–1787. [Google Scholar] [CrossRef] [Scilit]
- Zhang, Y.; Zhang, C.; Cai, X. Large-Signal Grid-Synchronization Stability Analysis of PLL-Based VSCs Using Lyapunov’s Direct Method. IEEE Trans. Power Syst. 2022, 37, 788–791. [Google Scholar] [CrossRef] [Scilit]
- Griffo, A.; Wang, J.; Howe, D. Large signal stability analysis of DC power systems with constant power loads. In Proceedings of the 2008 IEEE Vehicle Power and Propulsion Conference, Harbin, China, 3–5 September 2008. [Google Scholar] [CrossRef] [Scilit]
- Zhang, F.; Yan, Y. Start-up process and step response of a DCDC converter loaded by constant power loads. IEEE Trans. Ind. Electron. 2011, 58, 298–304. [Google Scholar] [CrossRef] [Scilit]
- Railway DC/DC Converters|Helios Power Solutions New Zealand. Available online: https://www.heliosps.co.nz/our-products/hps/dc-dc-converters/railway-converters/ (accessed on 14 January 2024).
- Zhang, D.; Cao, D.; Huber, J.; Everts, J.; Kolar, J.W. Advanced Synergetic Charge Control of Three-Phase PFC Buck-Boost Current DC-Link EV Chargers. In Proceedings of the 2022 IEEE 23rd Workshop on Control and Modeling for Power Electronics (COMPEL), Tel Aviv, Israel, 20–23 June 2022; pp. 1–8. [Google Scholar] [CrossRef] [Scilit]
- Wang, M.; Tang, F.; Wu, X.; Zhang, Y.; Wang, J. Passivation and Passivity-Based Control of DC-DC Converter With Unknown Constant Power Loads. IEEE J. Emerg. Sel. Top. Power Electron. 2022, 10, 4041–4058. [Google Scholar] [CrossRef] [Scilit]
- IEEE 1547-2018; IEEE Standard for Interconnection and Interoperability of Distributed Energy Resources with Associated Electric Power Systems Interfaces. IEEE Standards Association: Piscataway, NJ, USA, 2018.
- IEEE 946-2020; IEEE Recommended Practice for the Design of DC Power Systems for Stationary Applications. IEEE Standards Association: Piscataway, NJ, USA, 2020.
- Galkin, I.A.; Blinov, A.; Vorobyov, M.; Bubovich, A.; Saltanovs, R.; Peftitsis, D. Interface Converters for Residential Battery Energy Storage Systems: Practices, Difficulties and Prospects. Energies 2021, 14, 3365. [Google Scholar] [CrossRef] [Scilit]
- IEC SMB/SG 4; LVDC Distribution Systems up to 1500V DC. IEC: Geneva, Switzerland, 2011.
- MIL-STD-1399; Interface Standard Section 300B Electric Power, Alternating Current. Department of Defense: Washington, VA, USA, 1990.
- EN 50155:2017; Railway Applications—Rolling Stock—Electronic Equipment. European Commission: Brussels, Belgium, 2017.
- EN 61000-4-4:2012; Electromagnetic Compatibility (EMC)—Part 4-4: Testing and Measurement Techniques—Electrical Fast Transient/Burst Immunity Test. European Commission: Brussels, Belgium, 2012.
- EN 50121-3-2:2017; Railway Applications—Electromagnetic Compatibility—Part 3-2: Rolling Stock—Apparatus. European Commission: Brussels, Belgium, 2017.
- IEC 60950-1:2005; Information Technology Equipment—Safety—Part 1: General Requirements. IEC: Geneva, Switzerland, 2005.
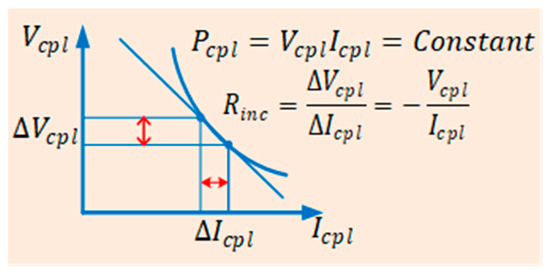
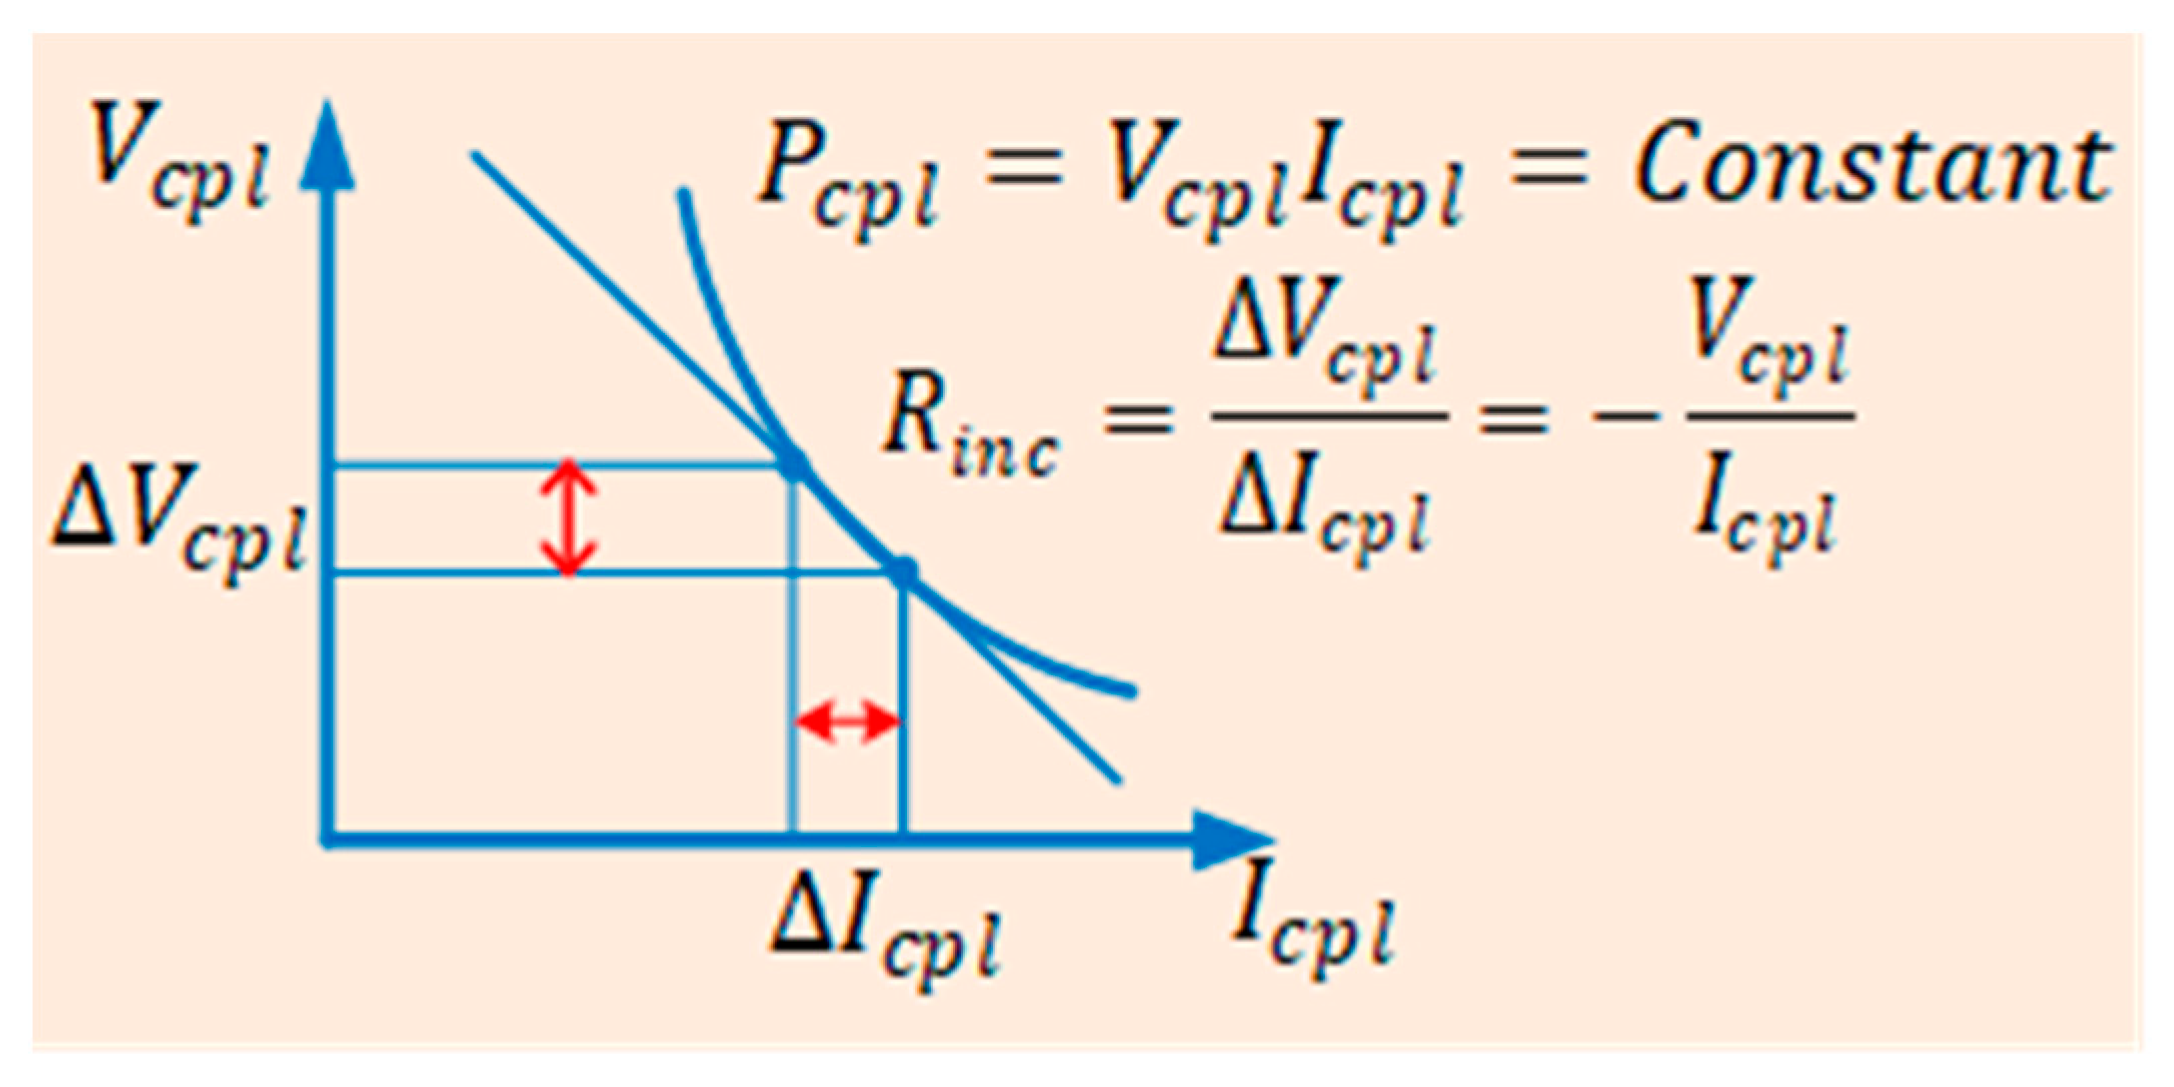
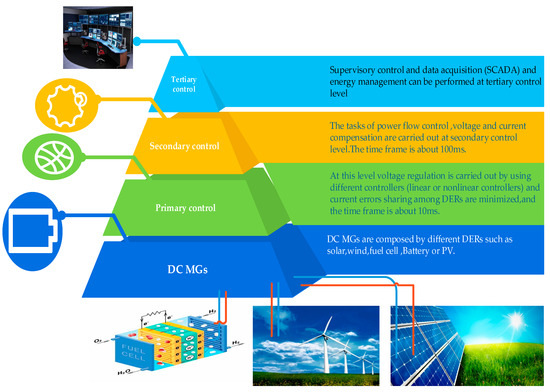
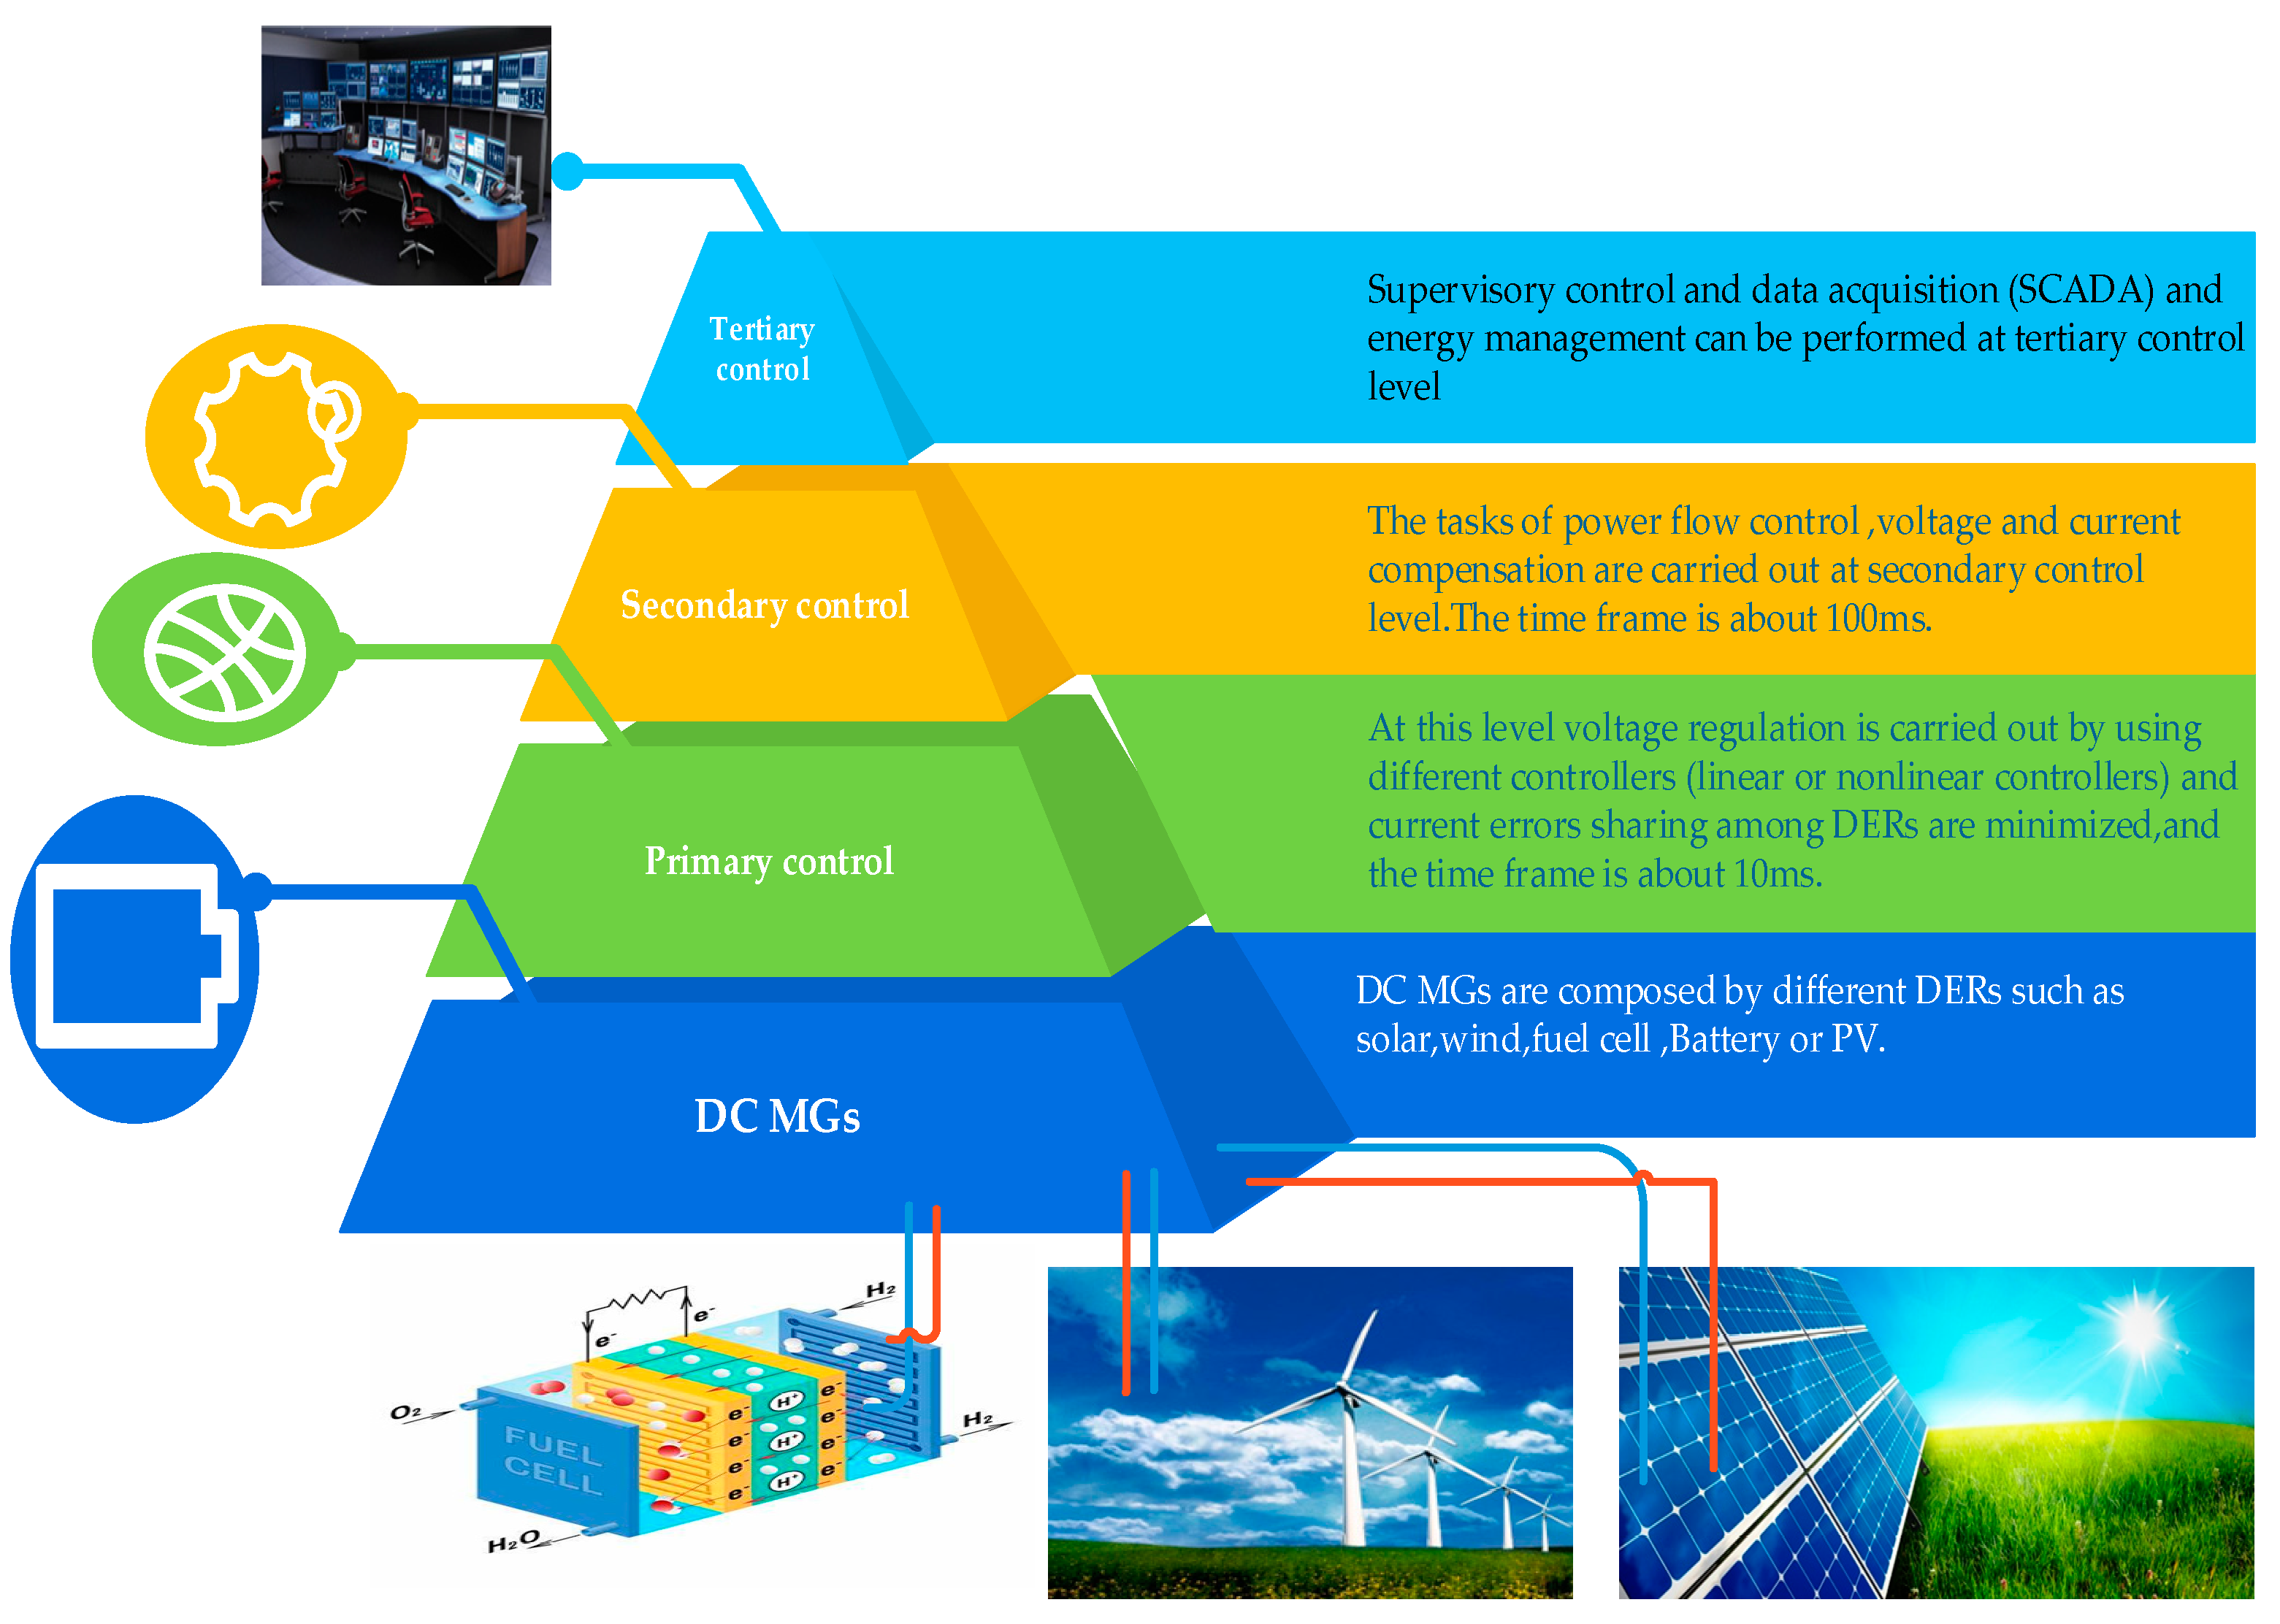
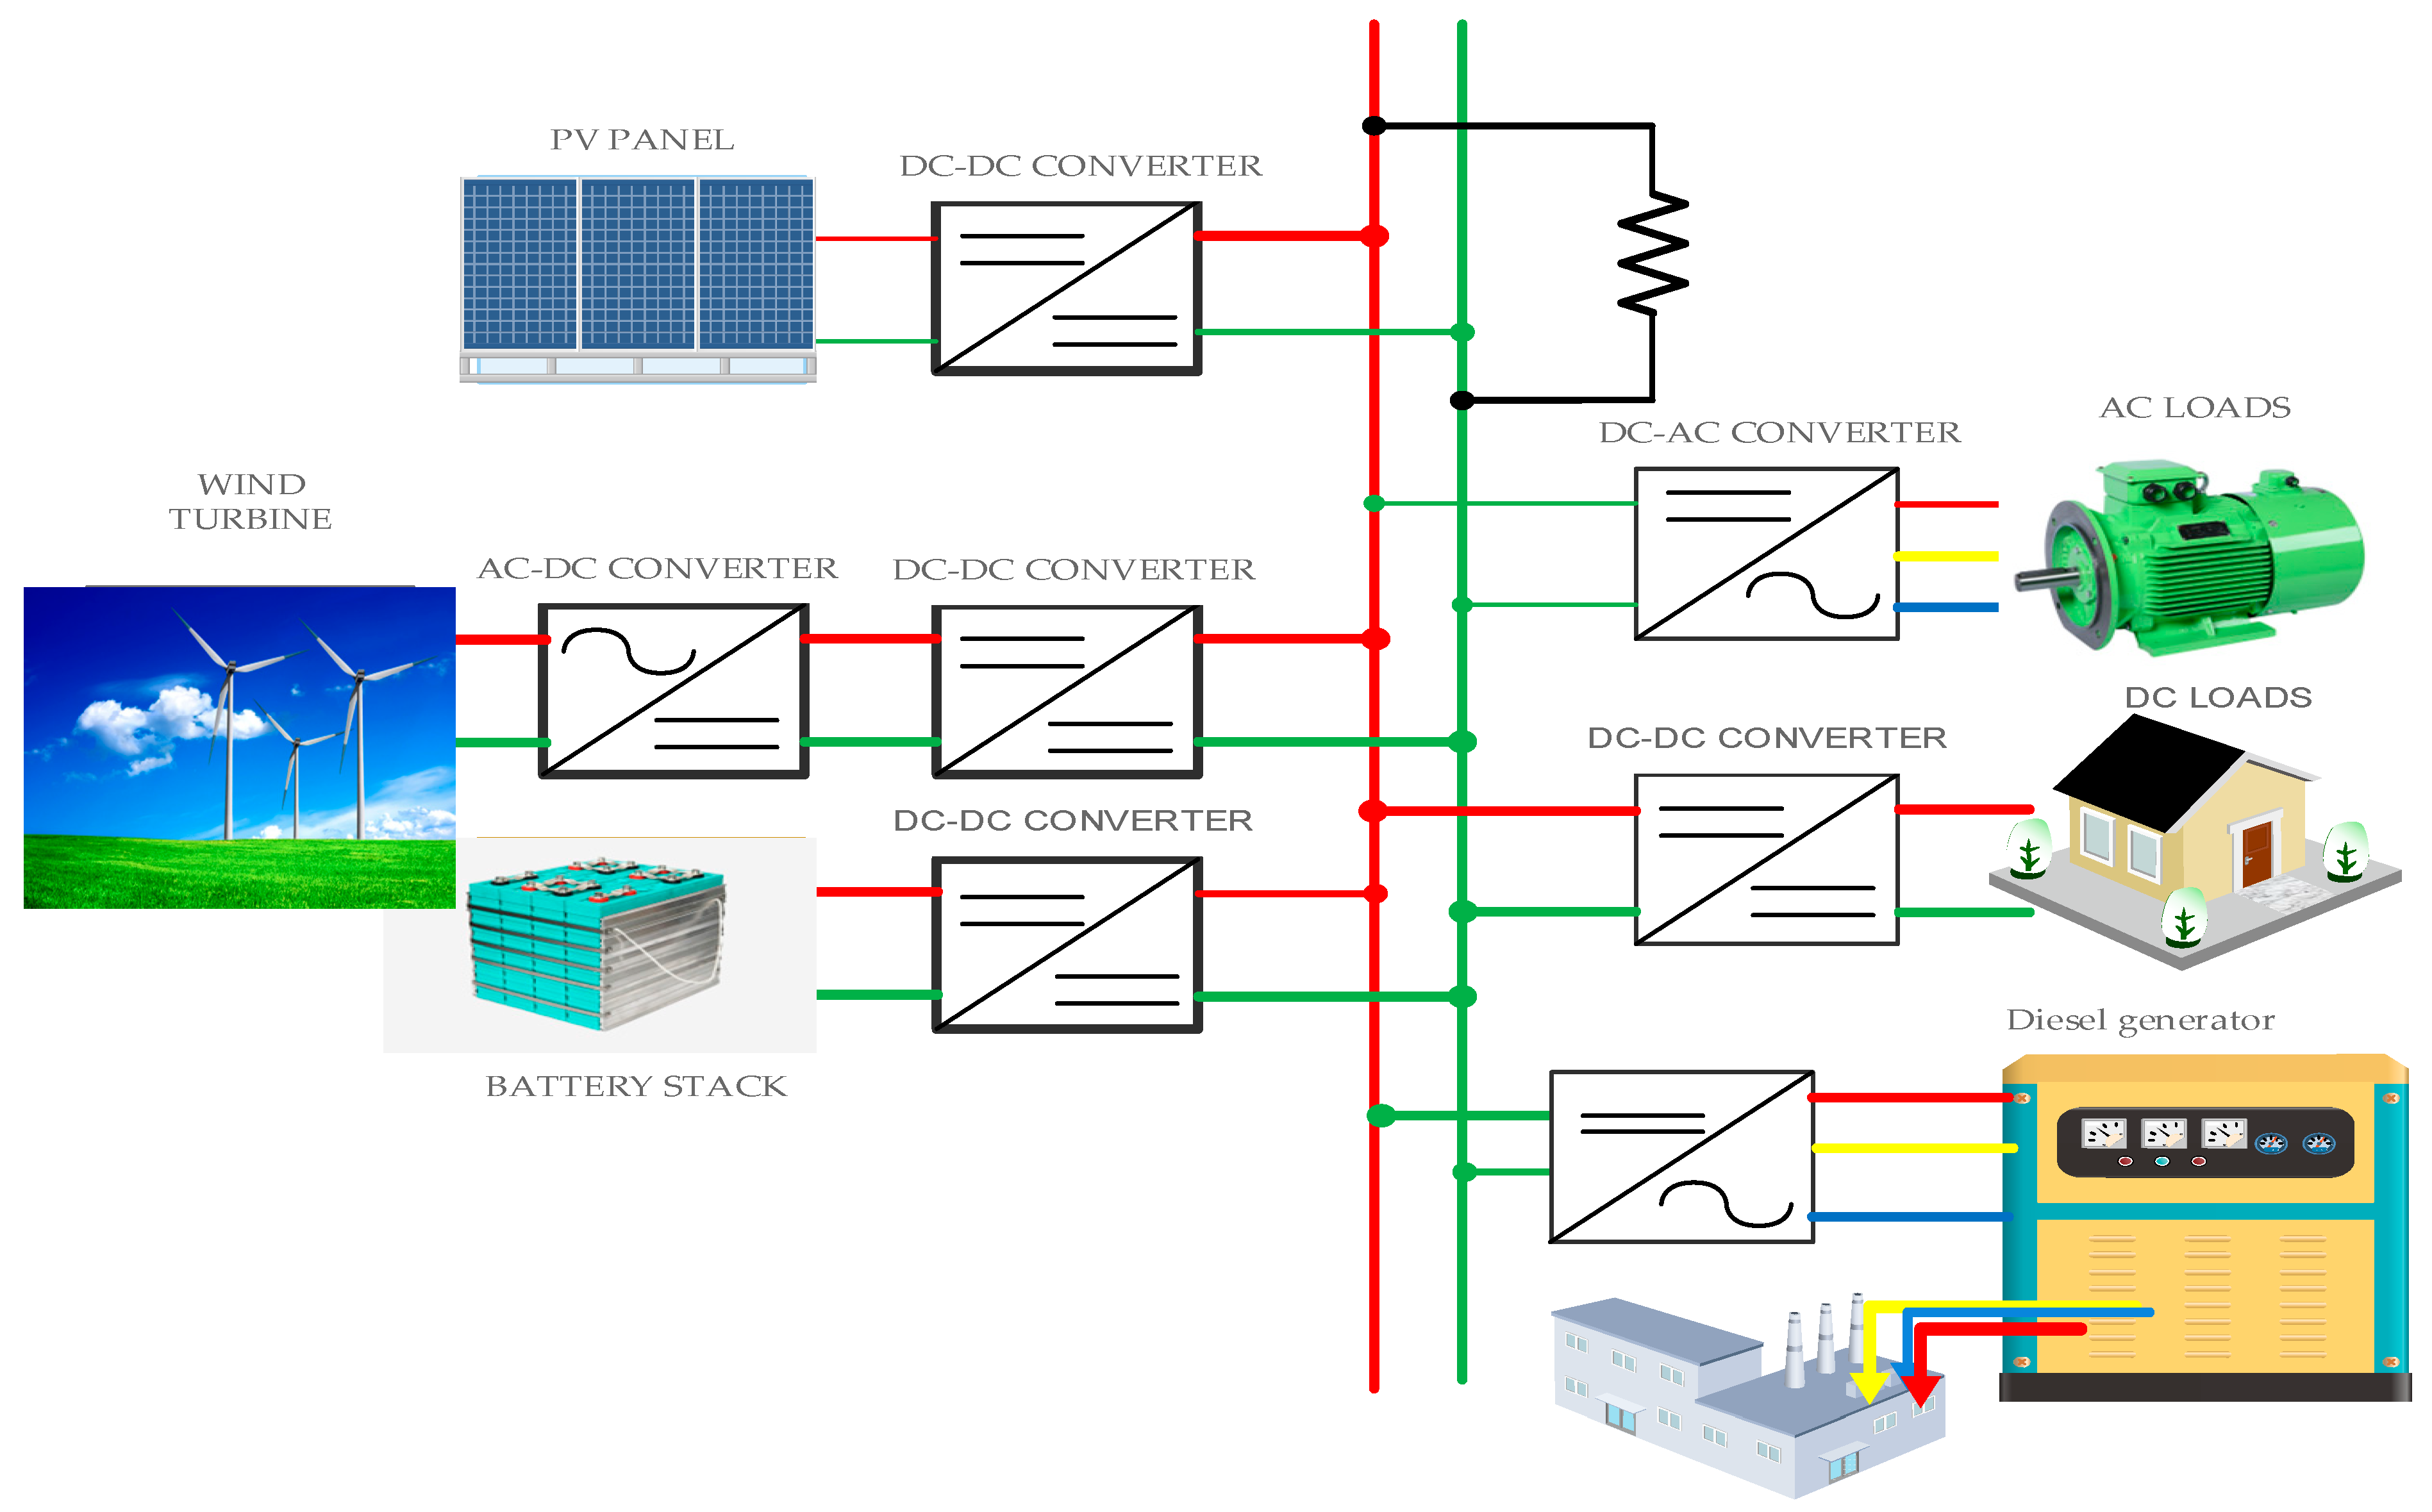
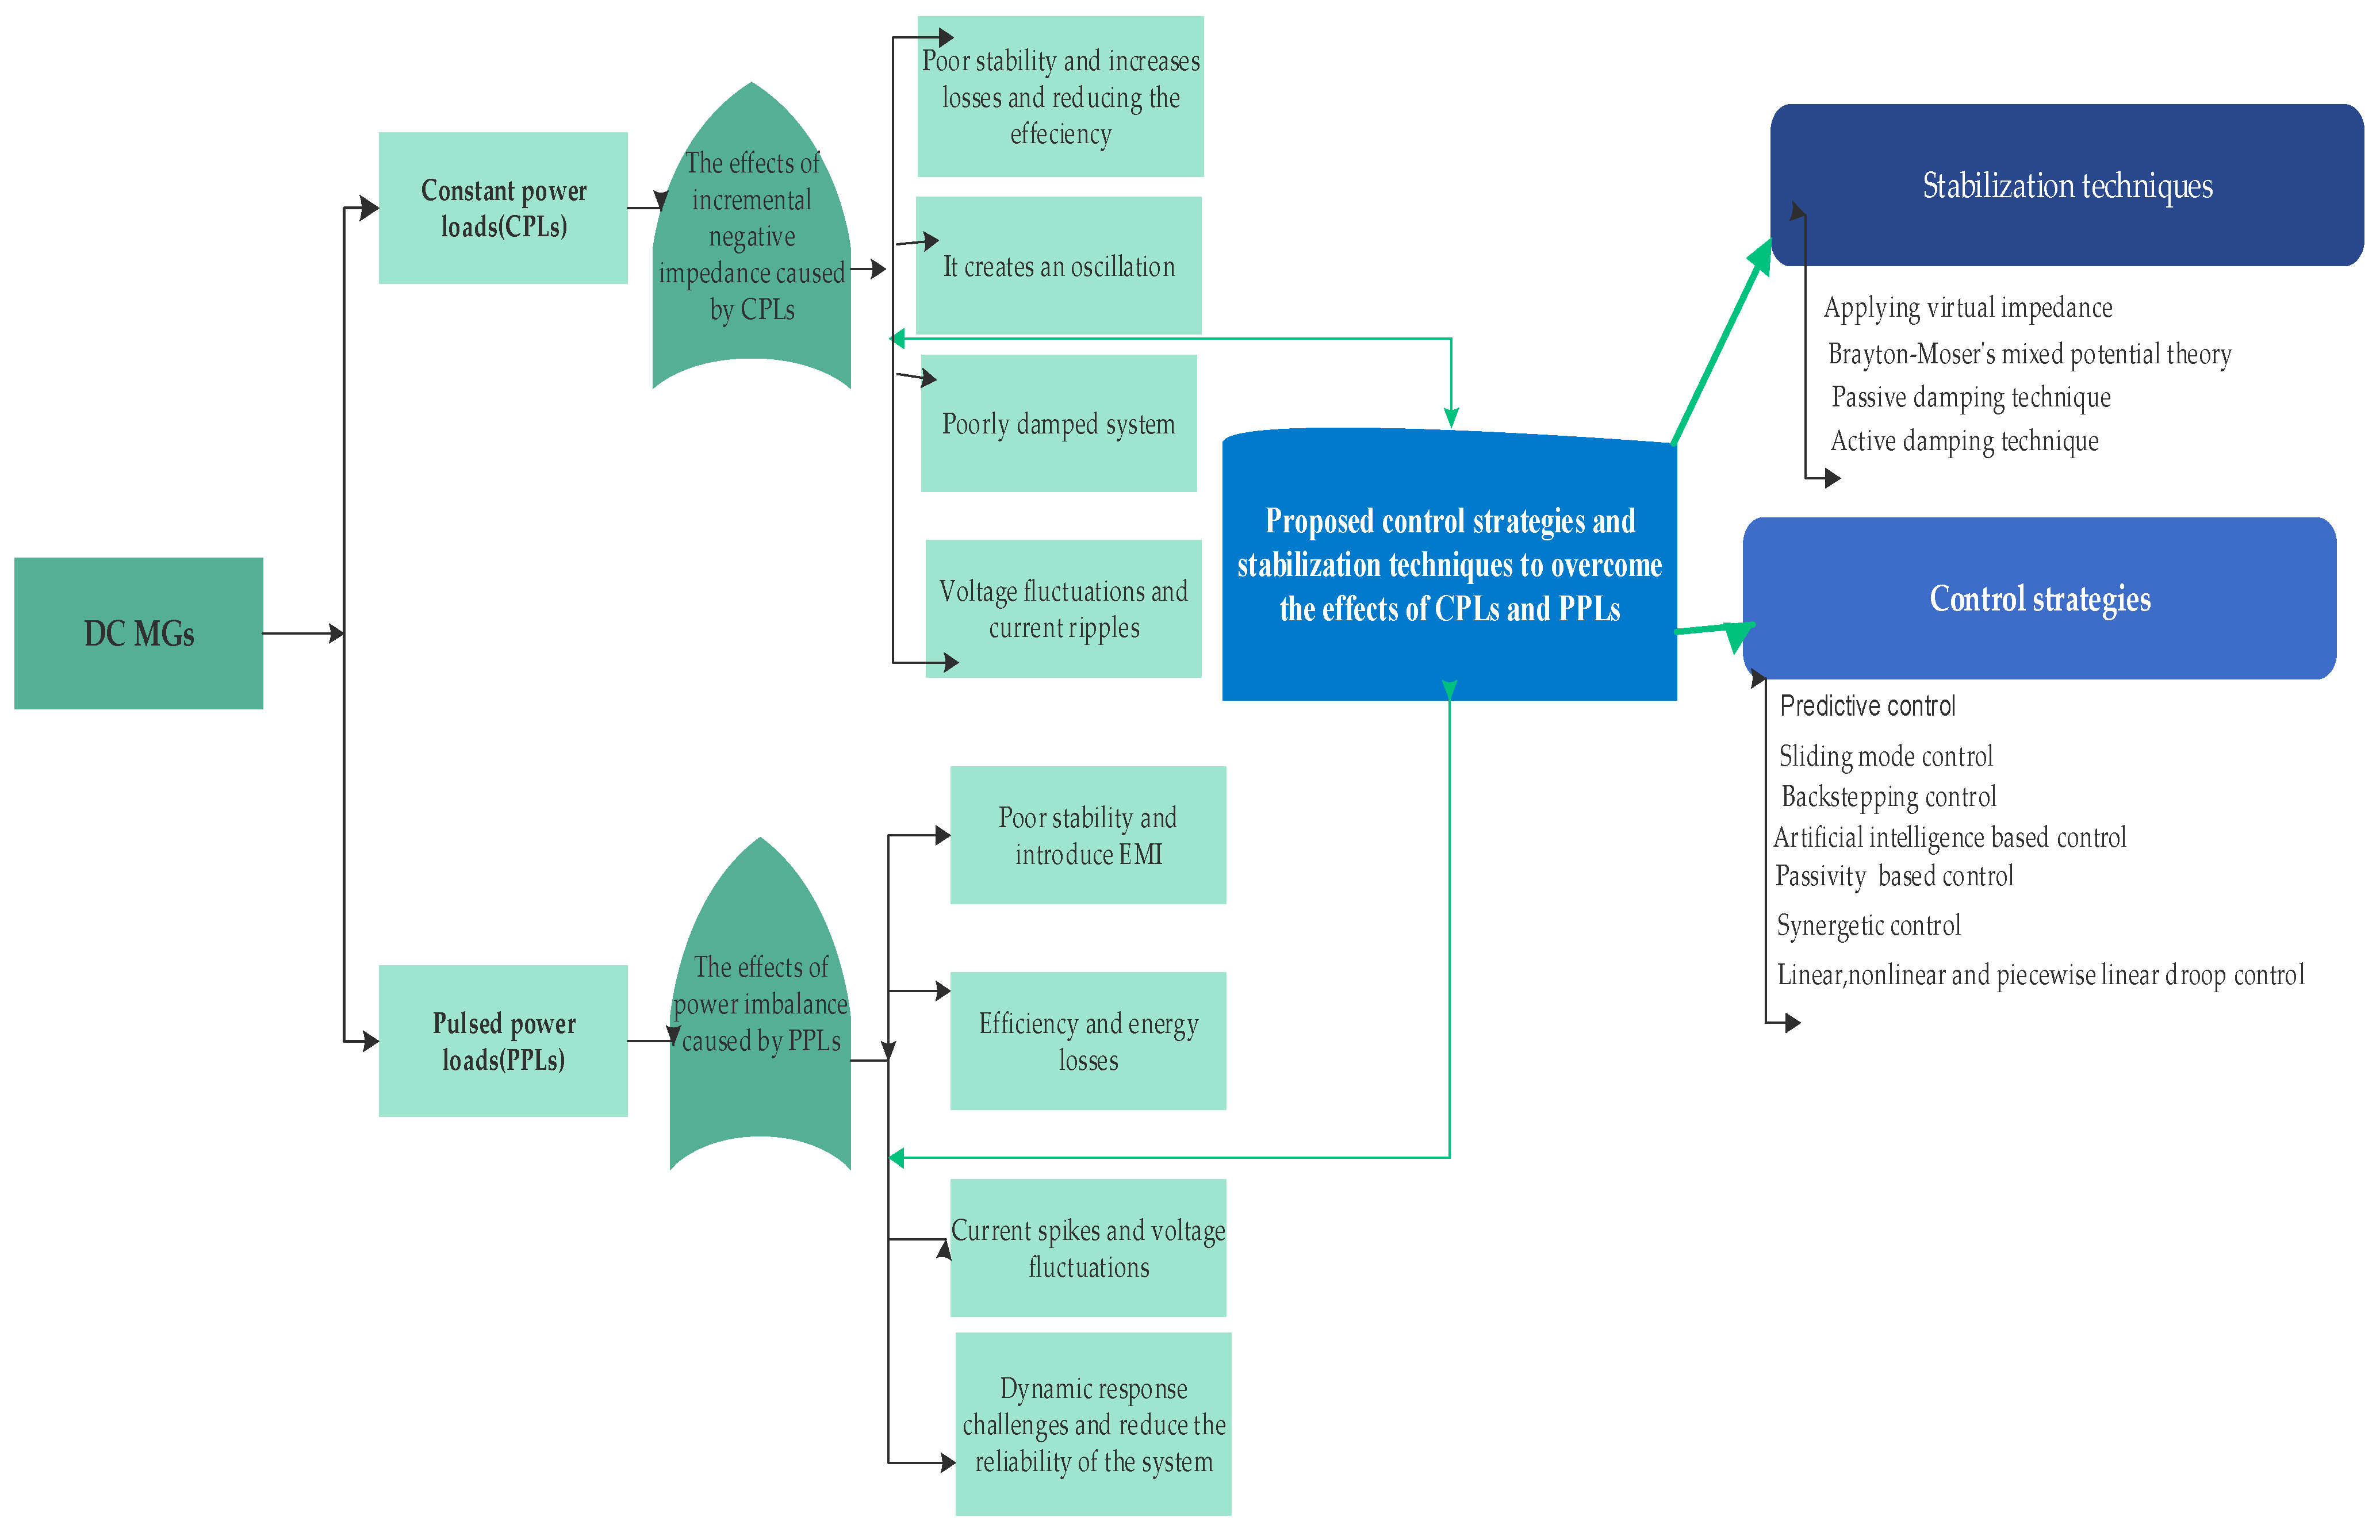
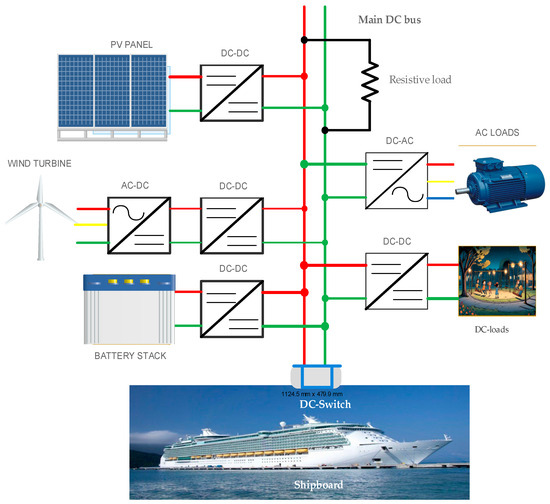
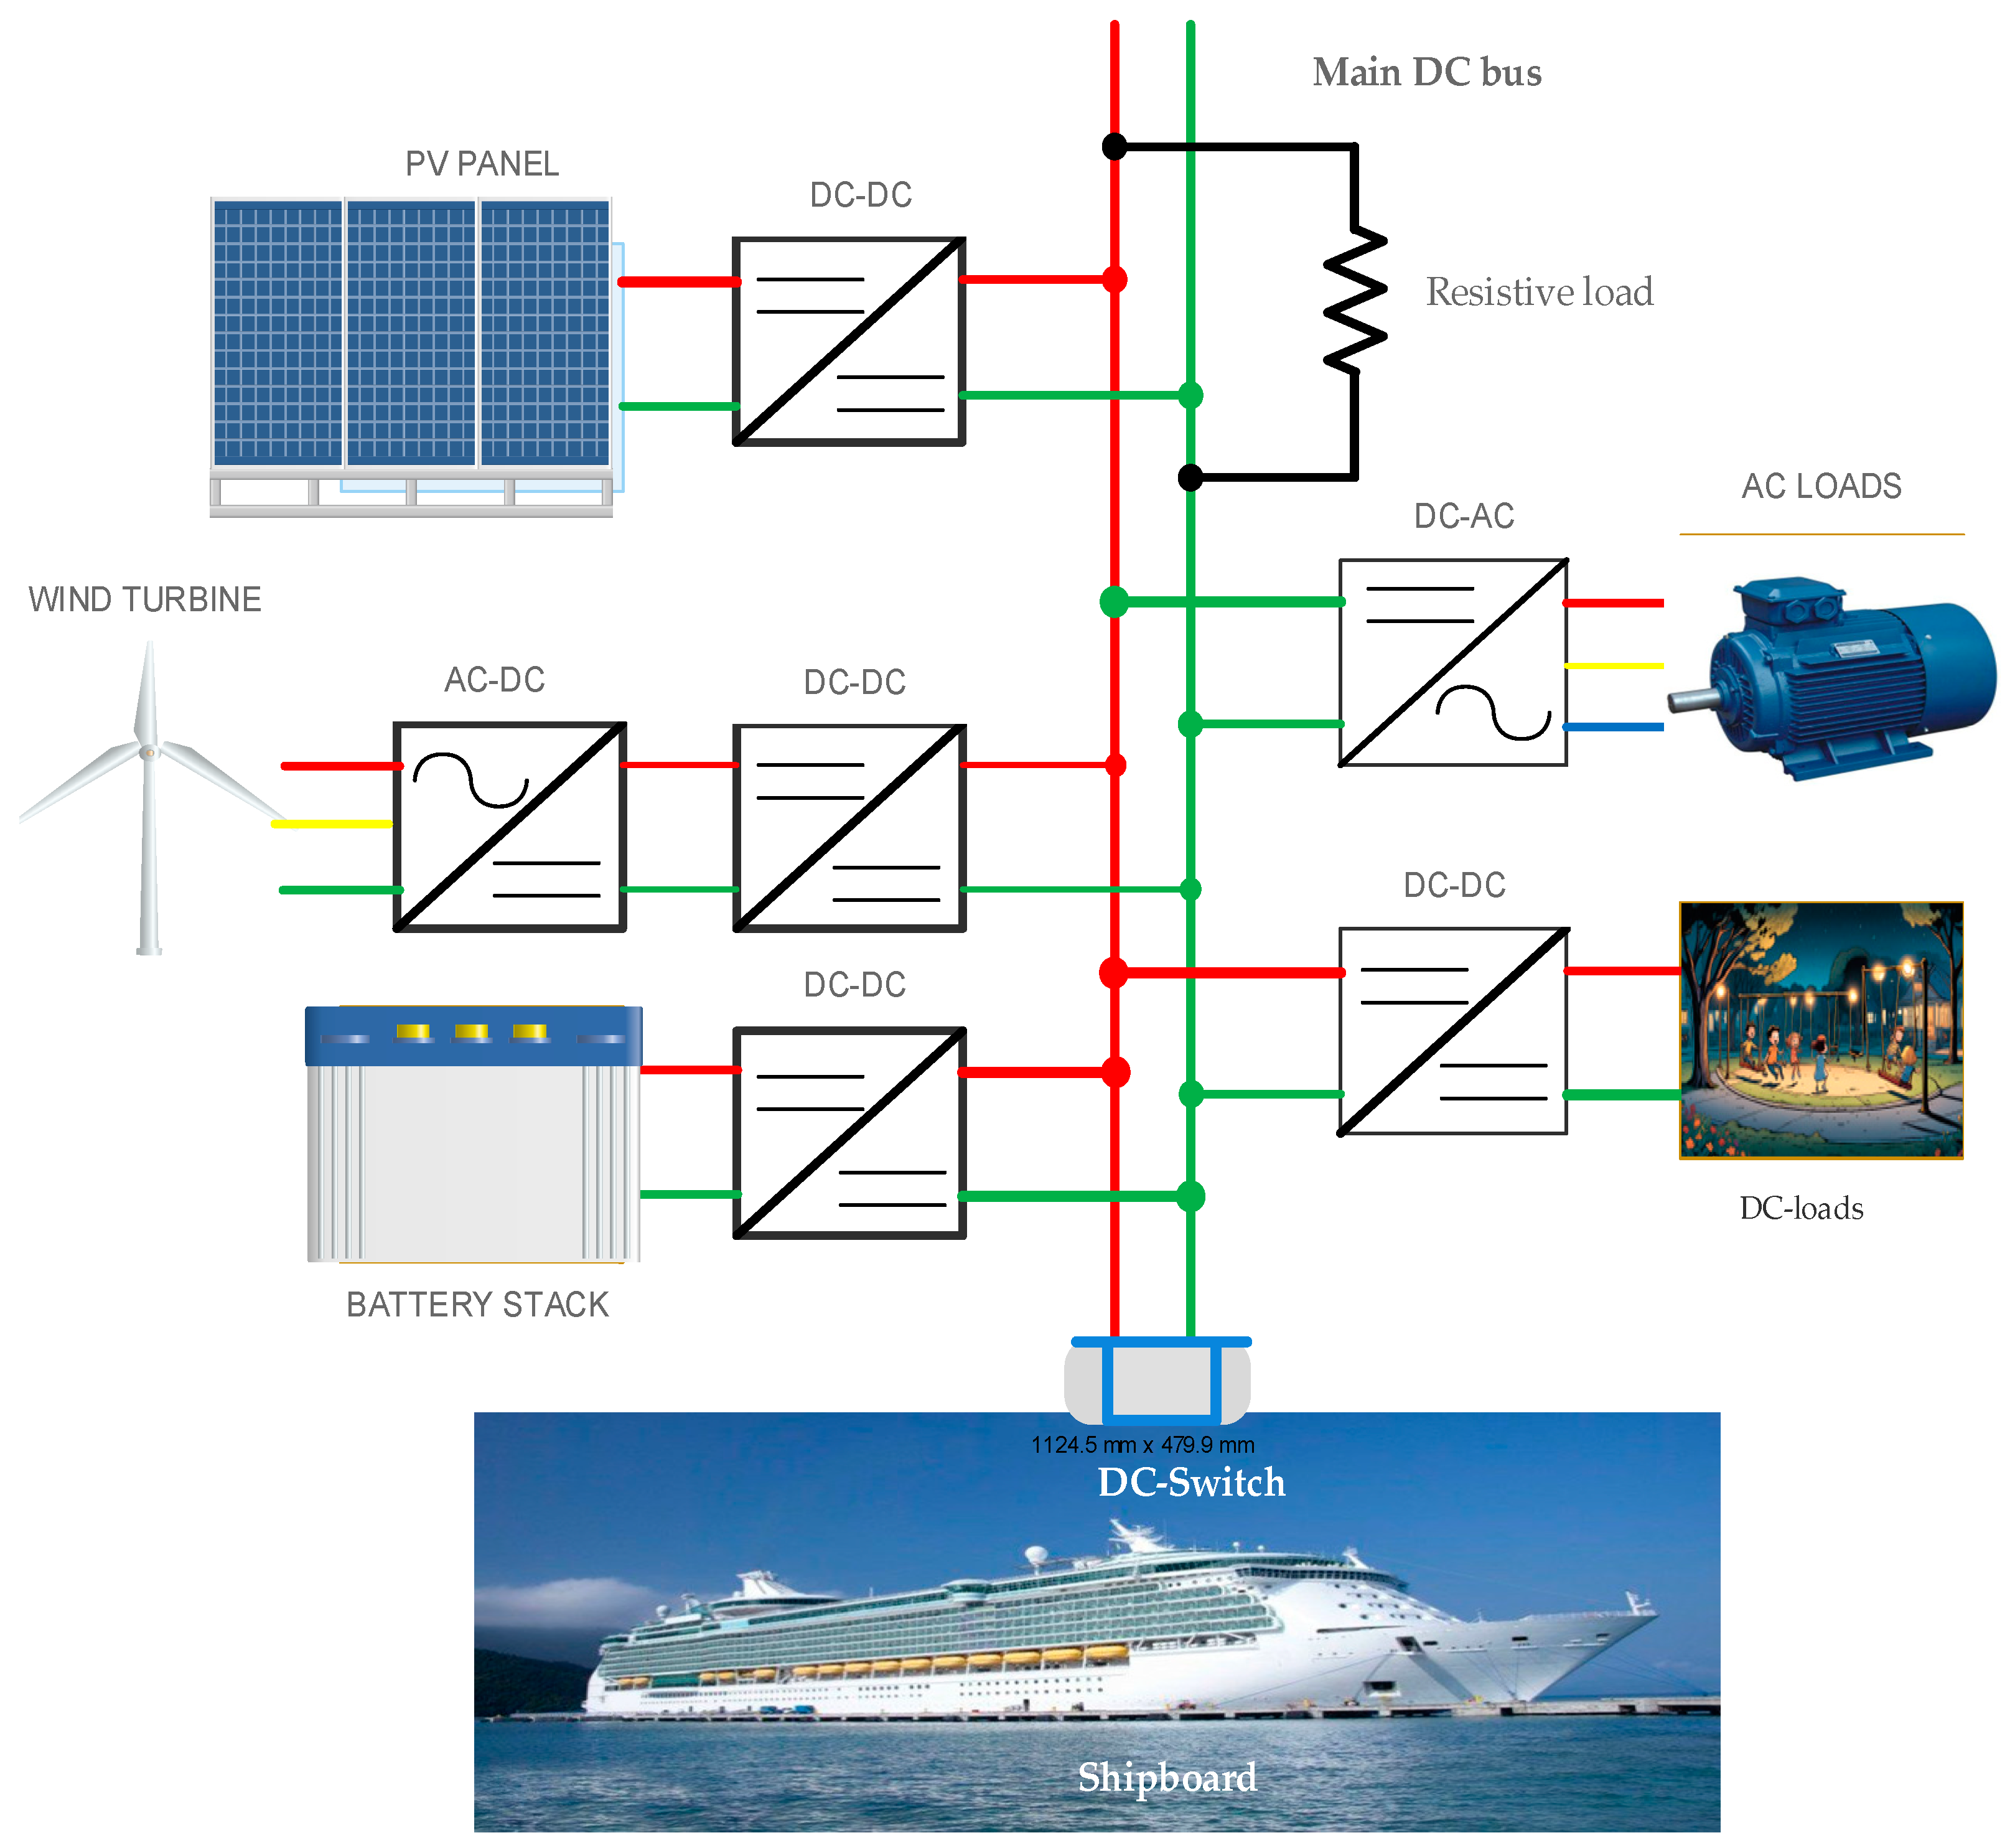
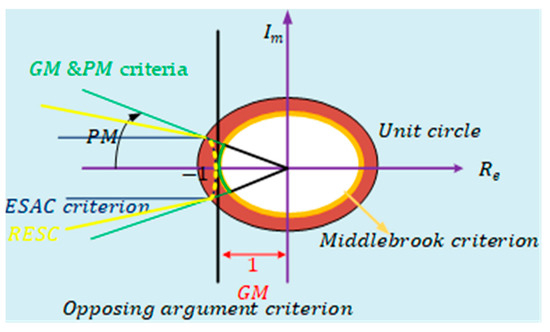
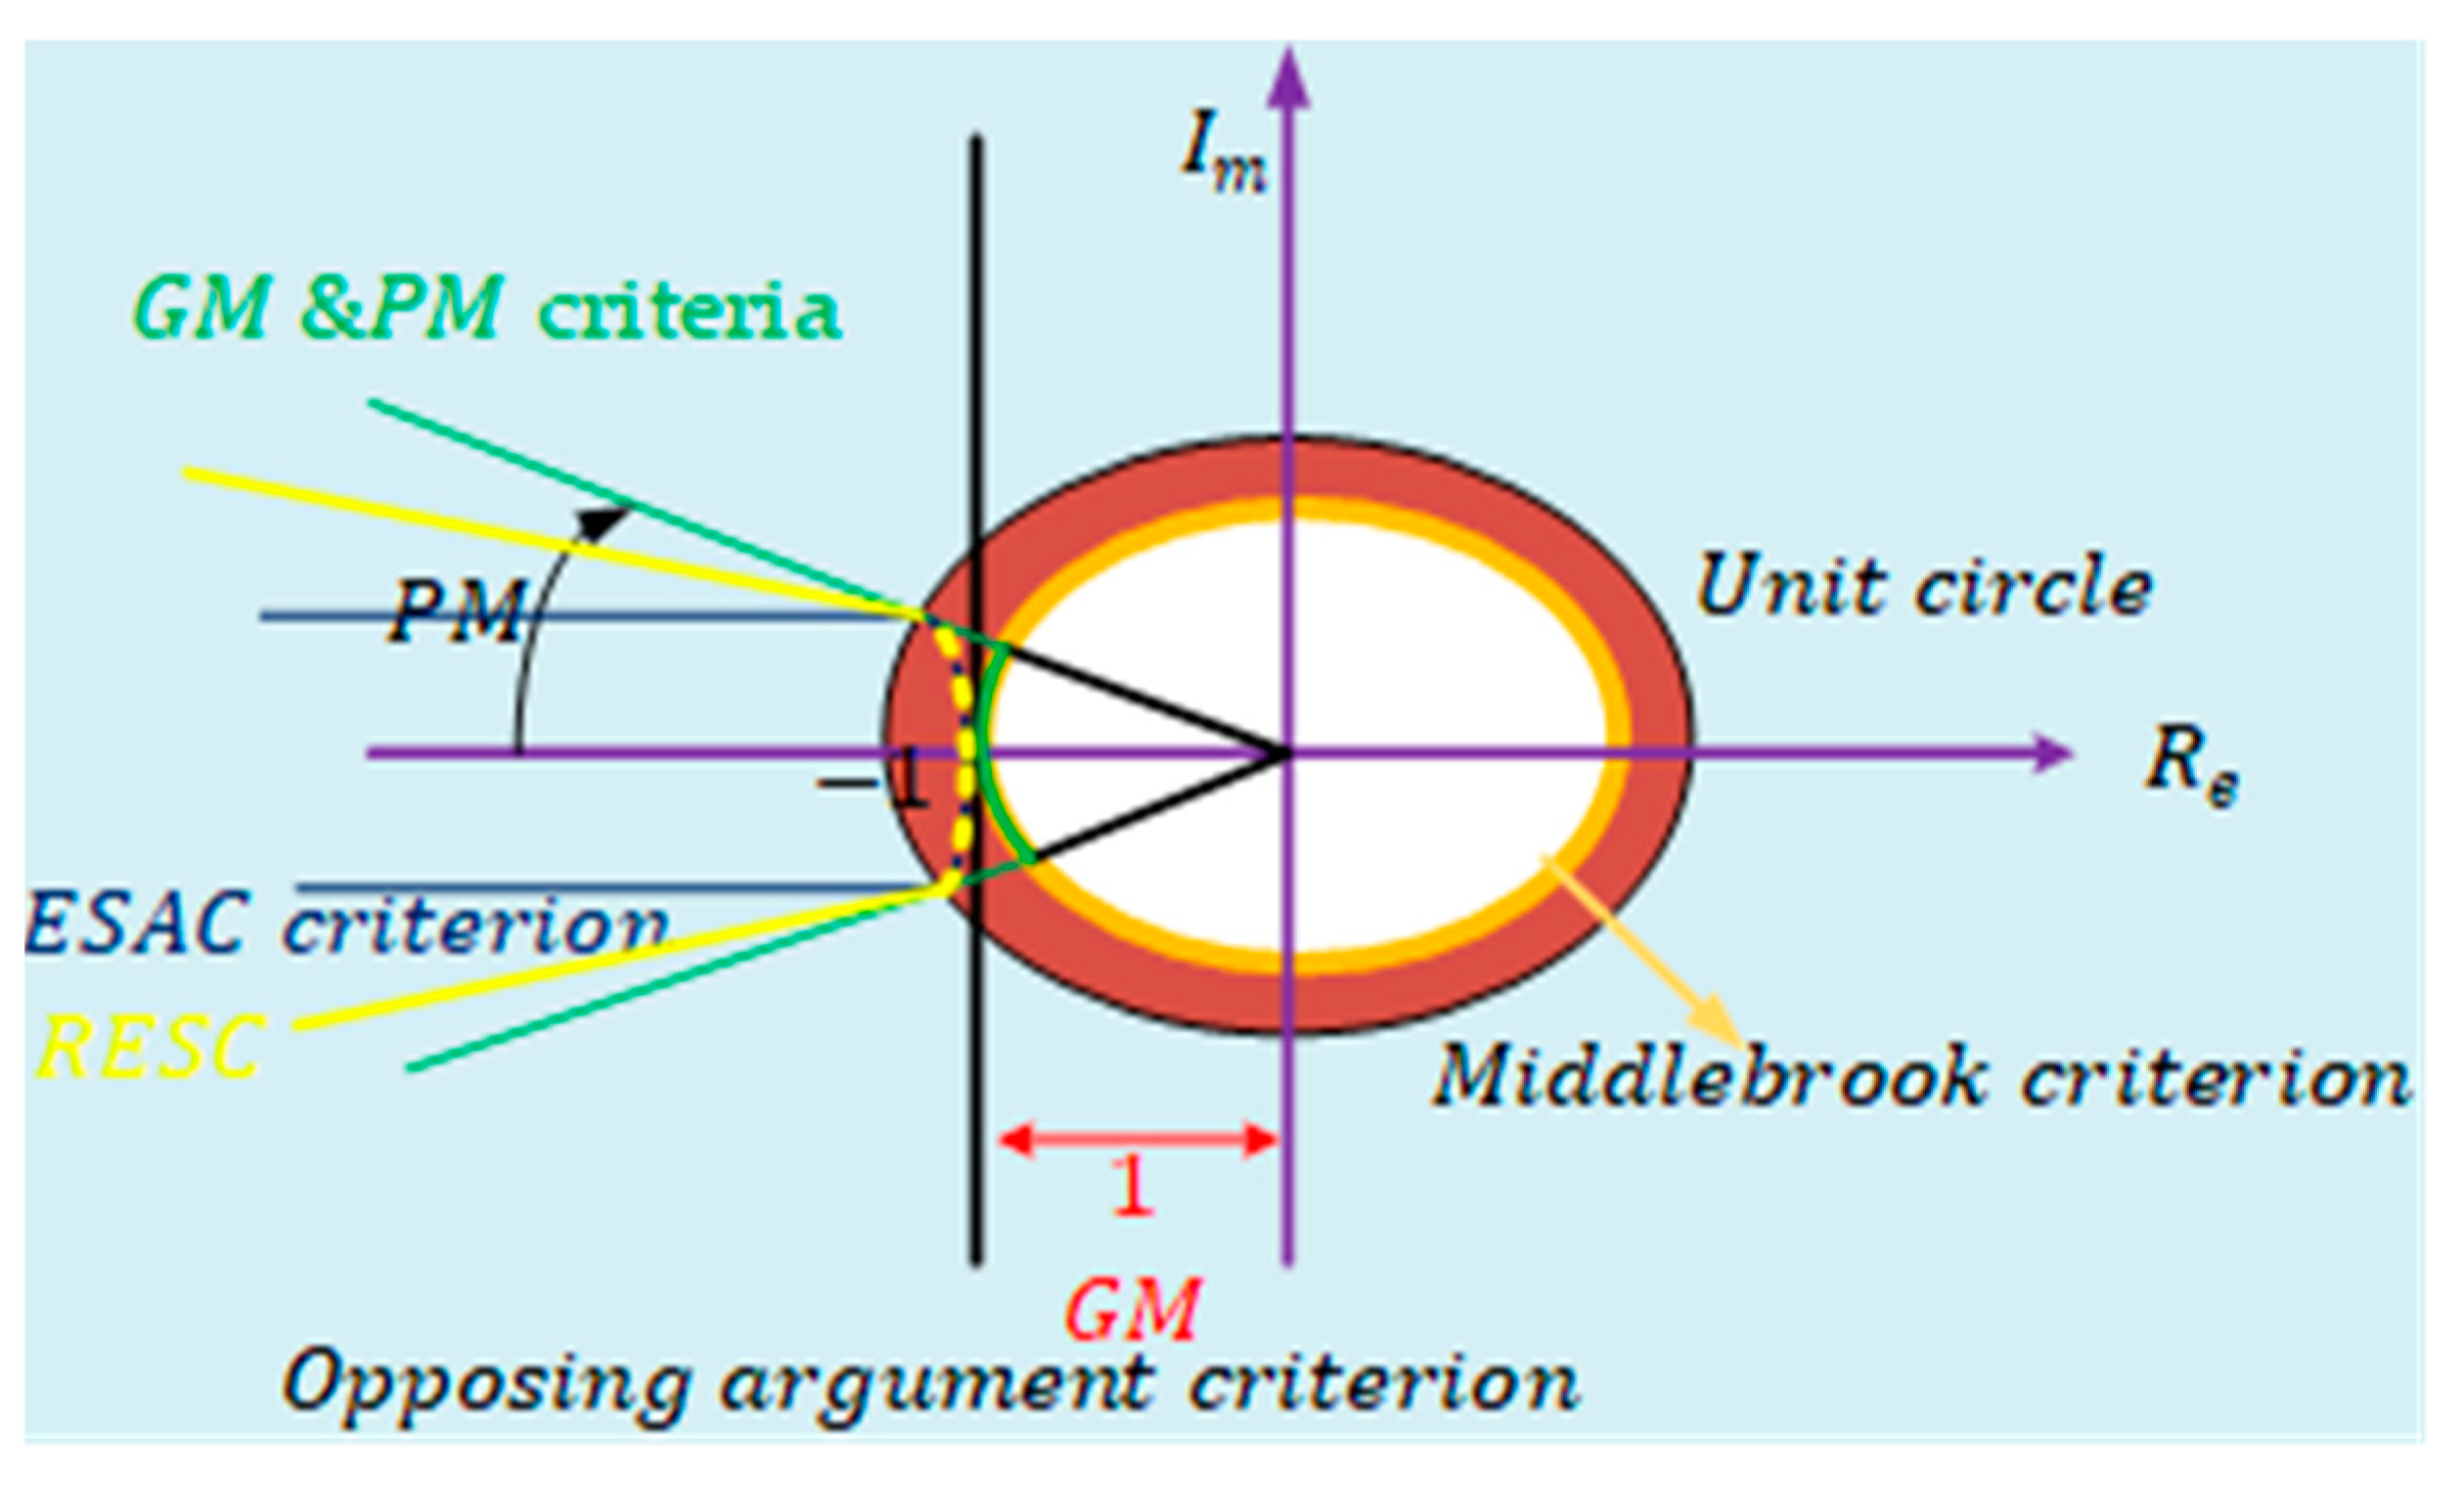
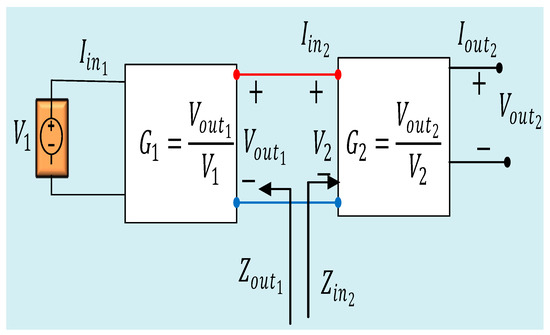
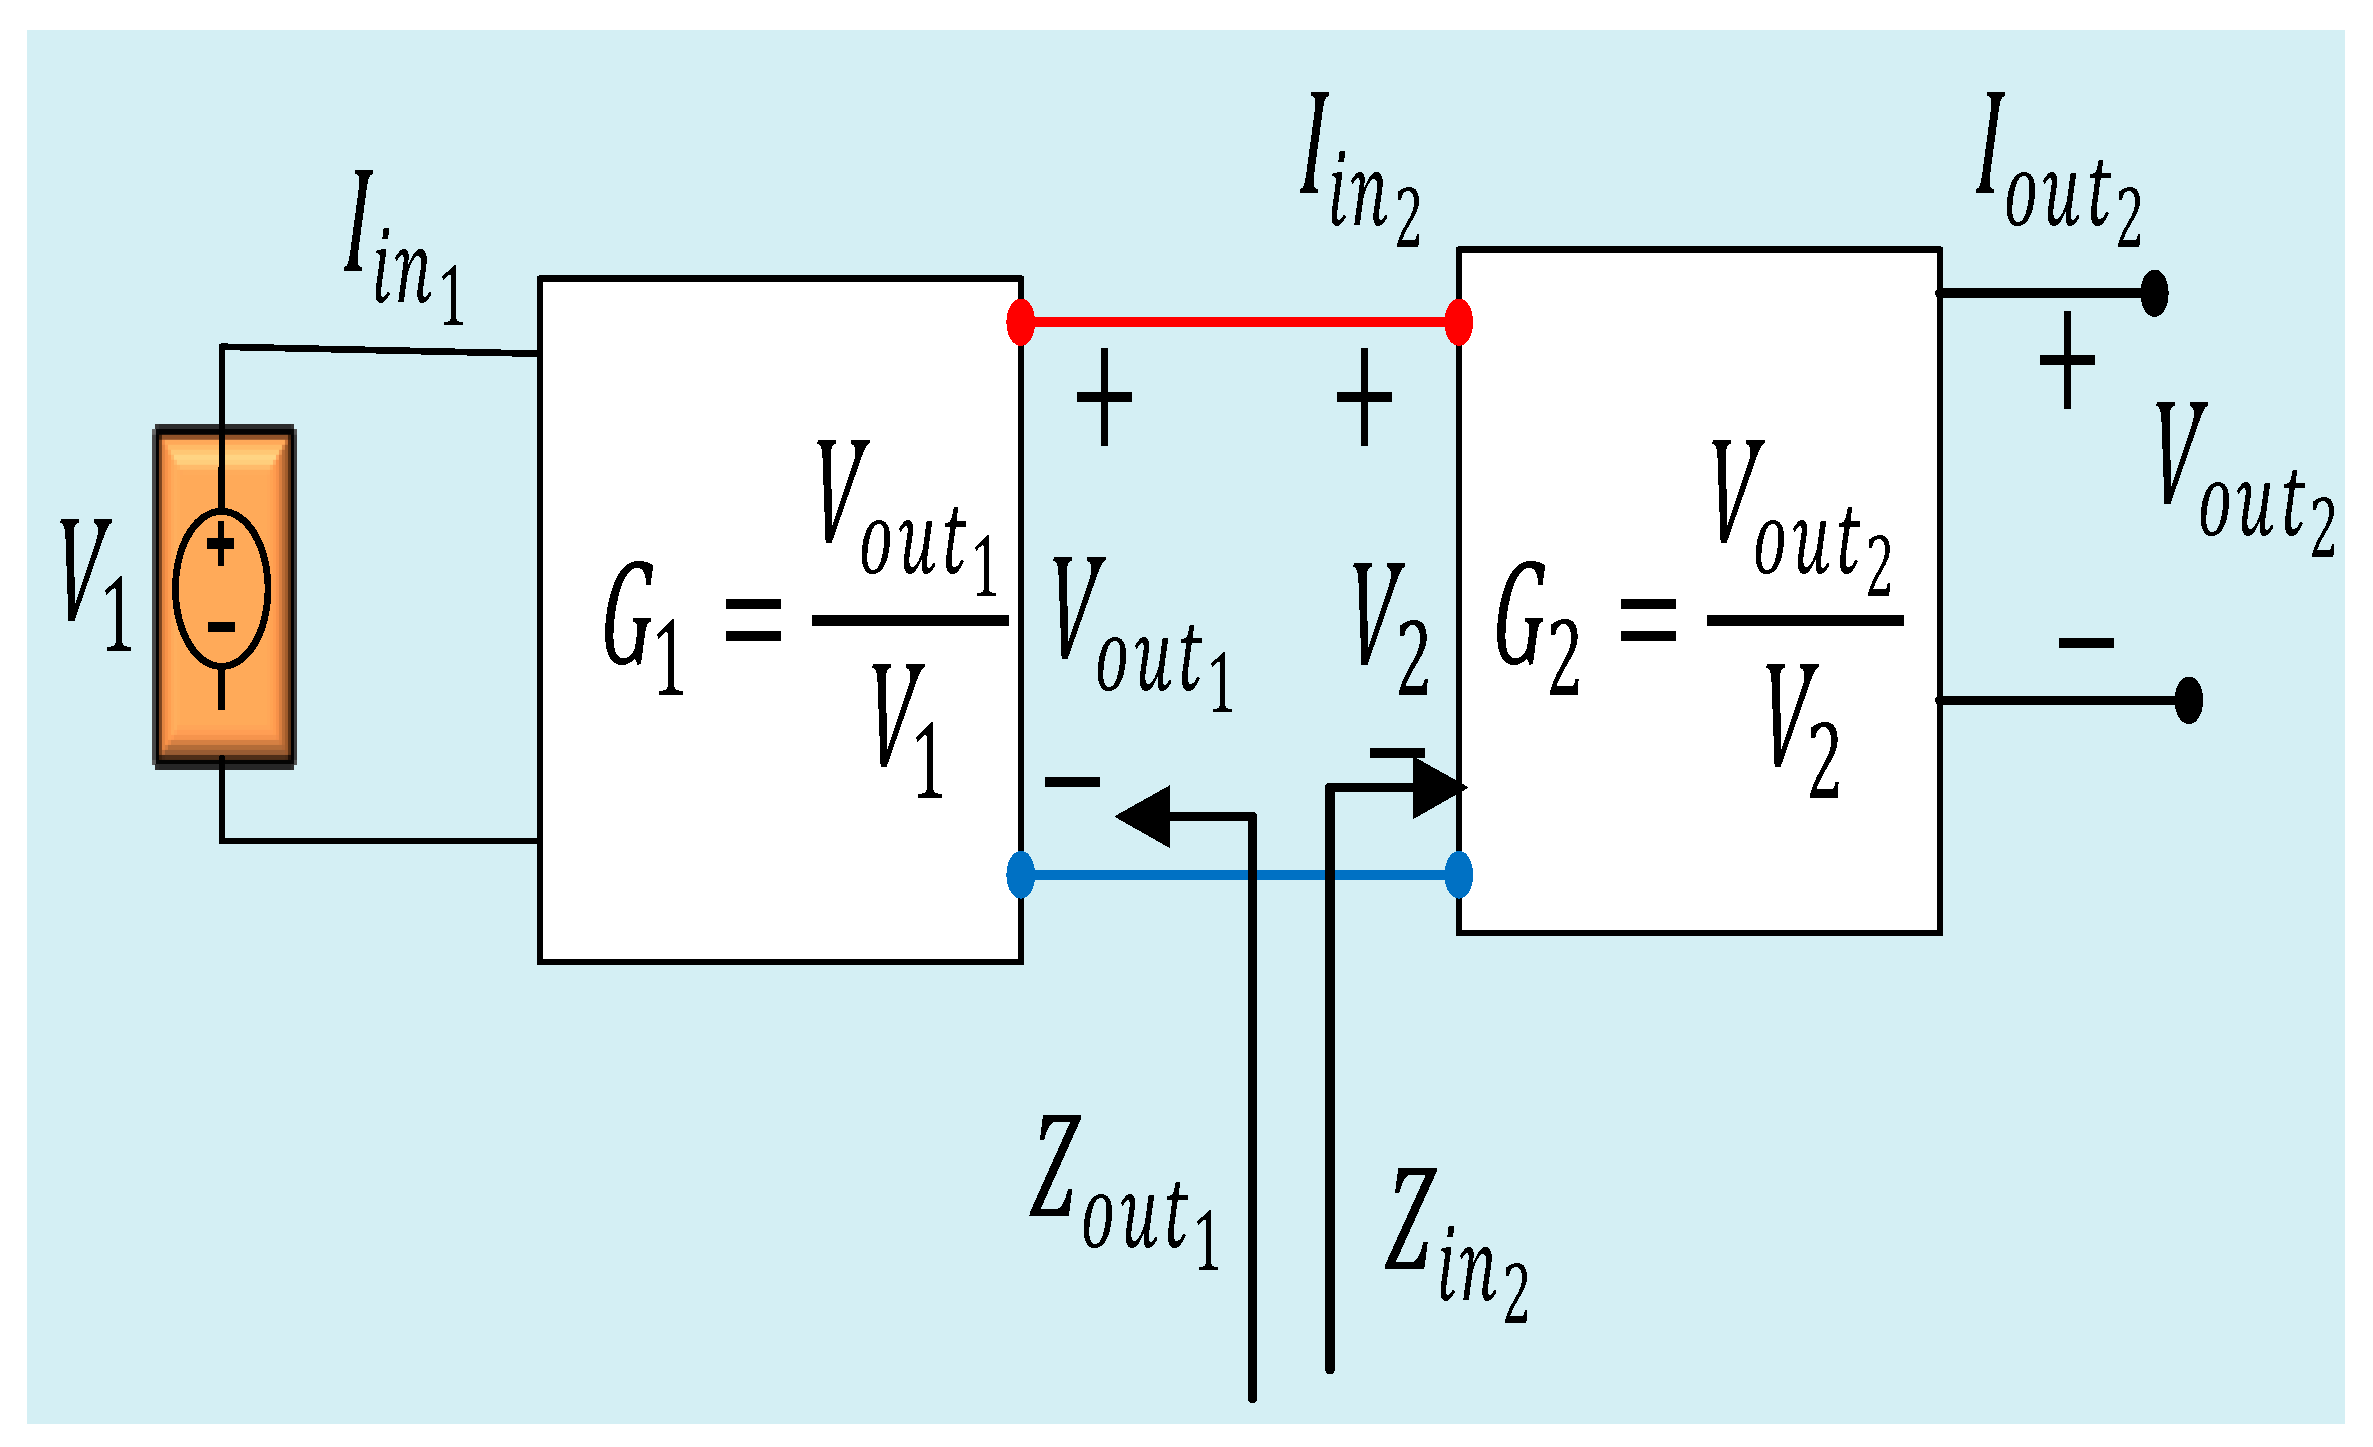
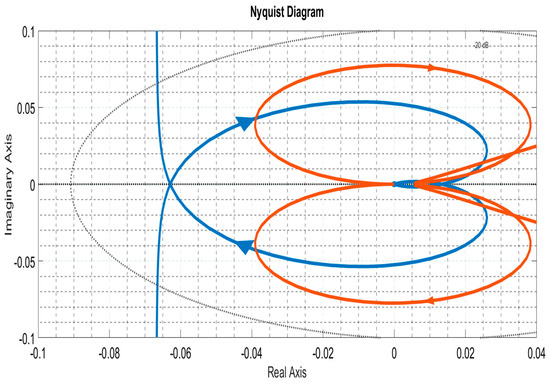
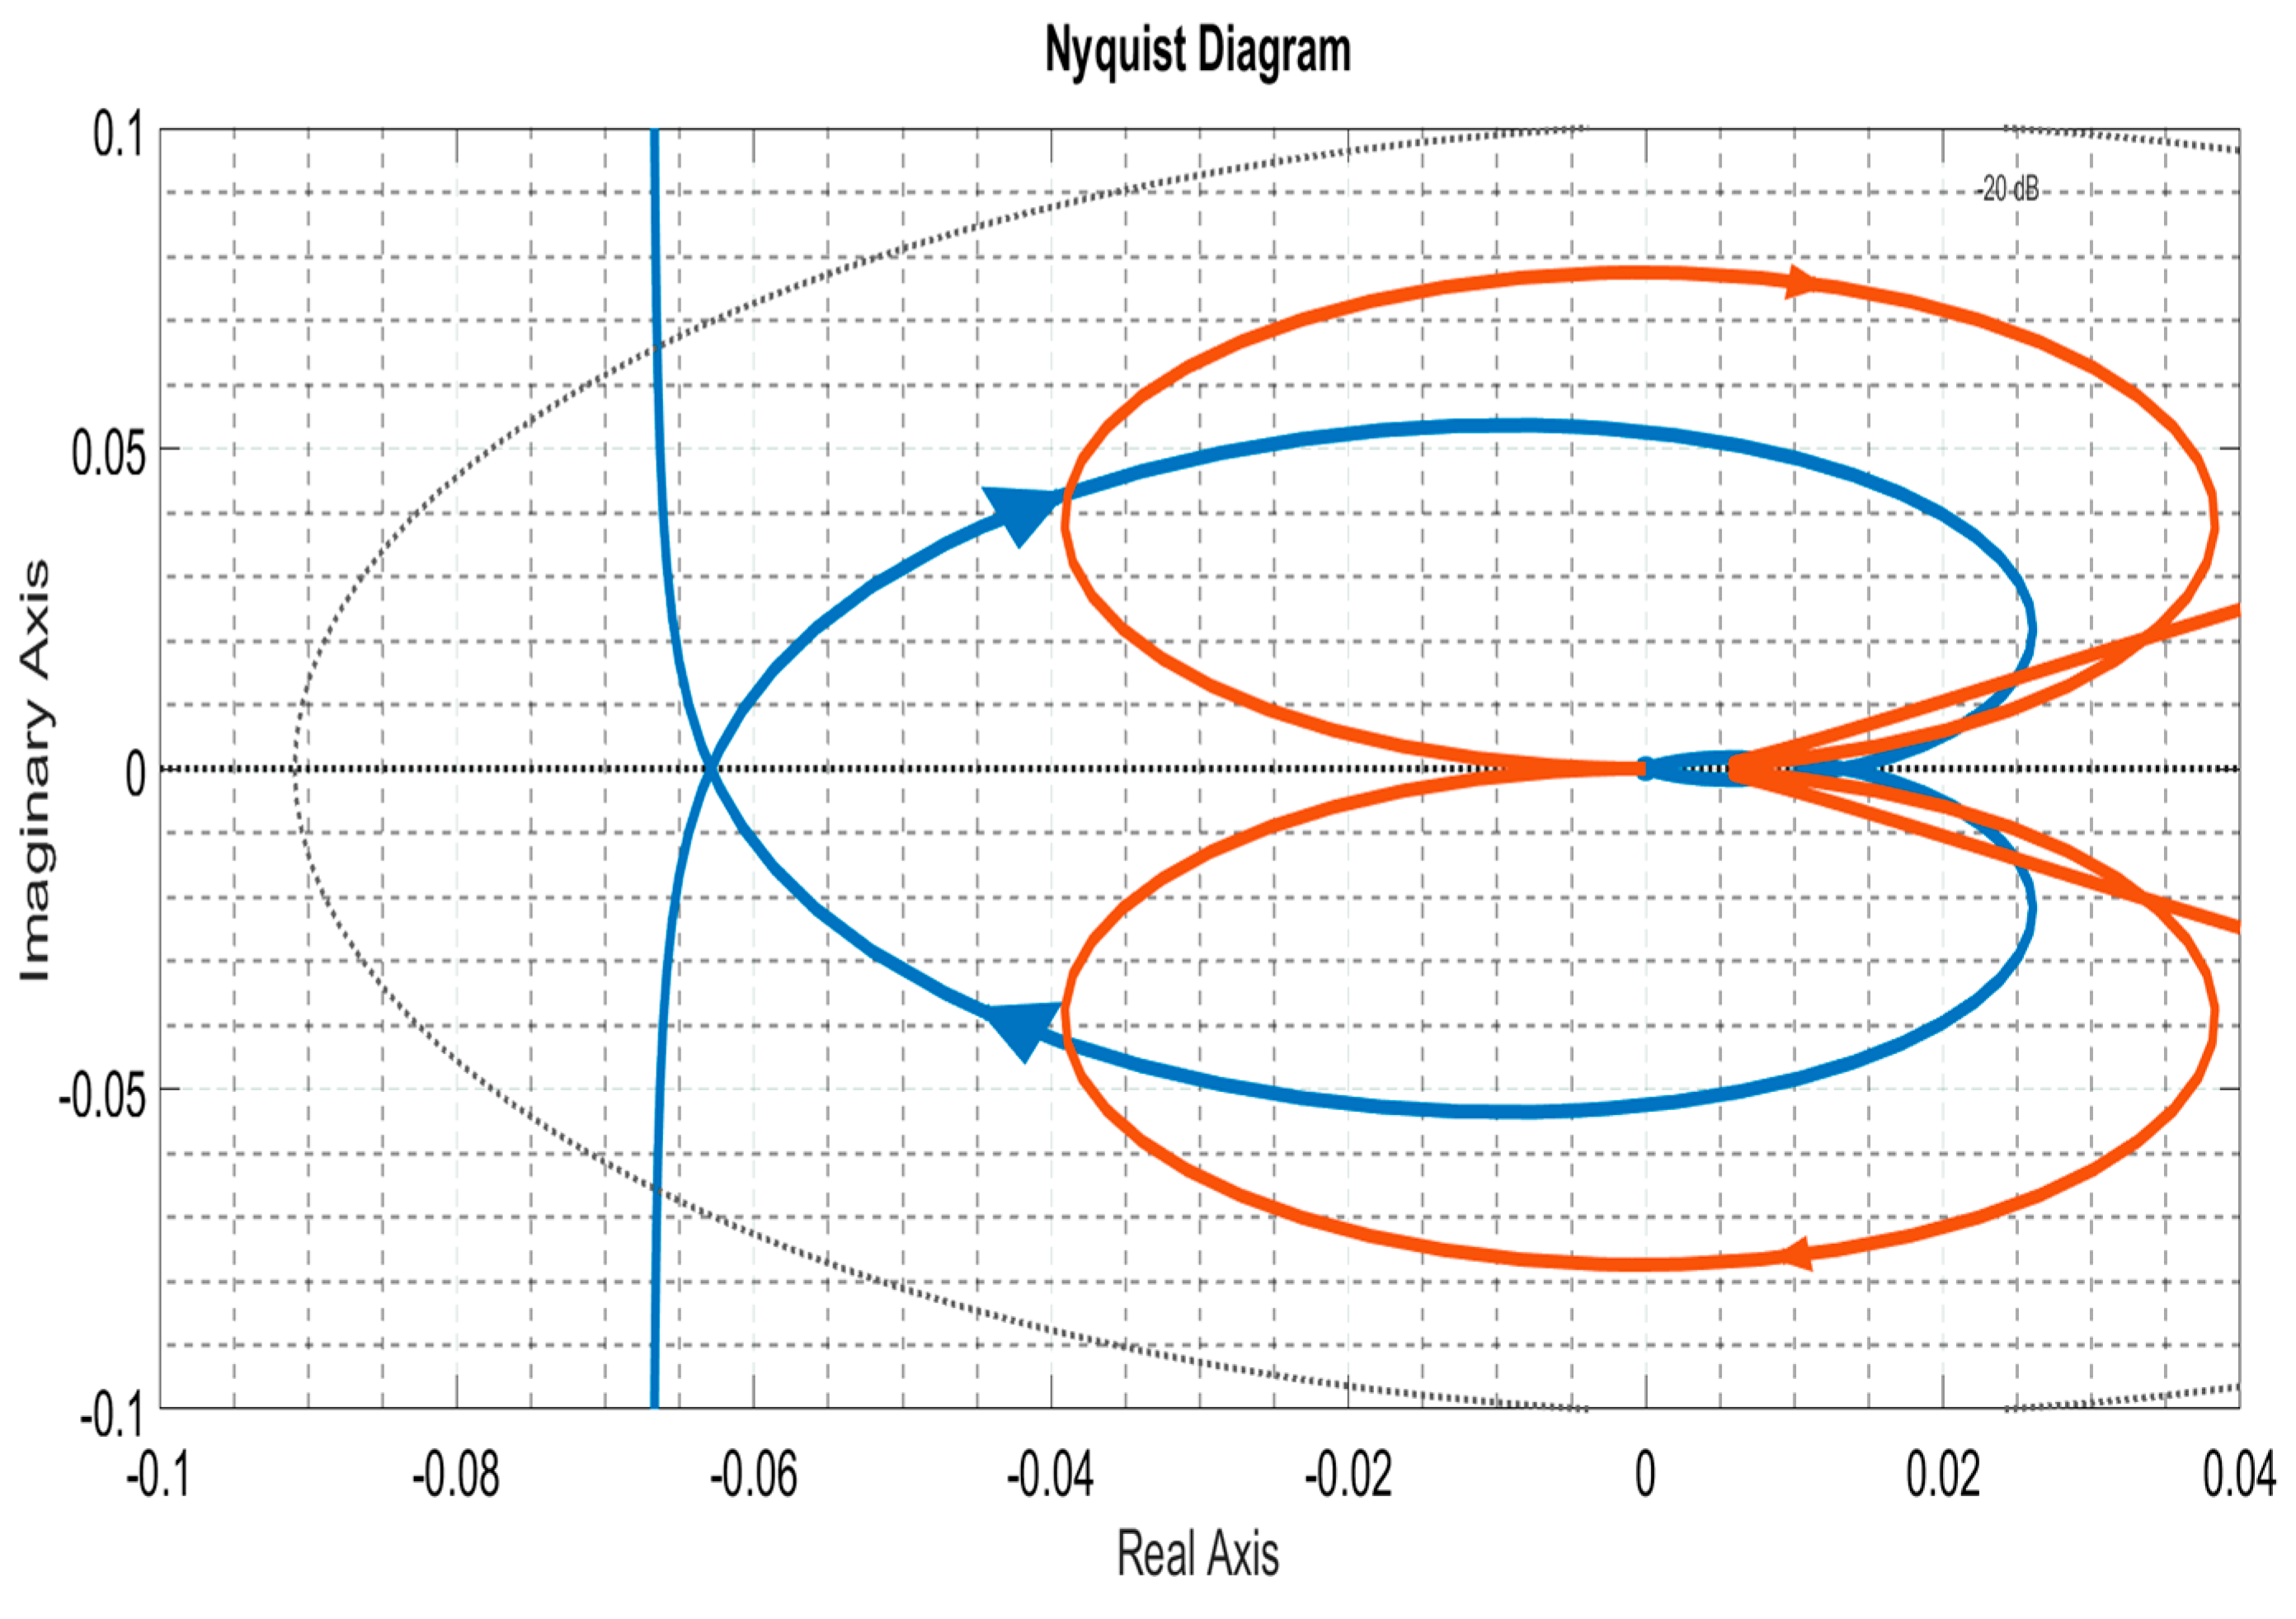
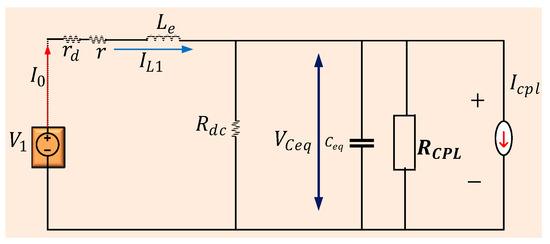
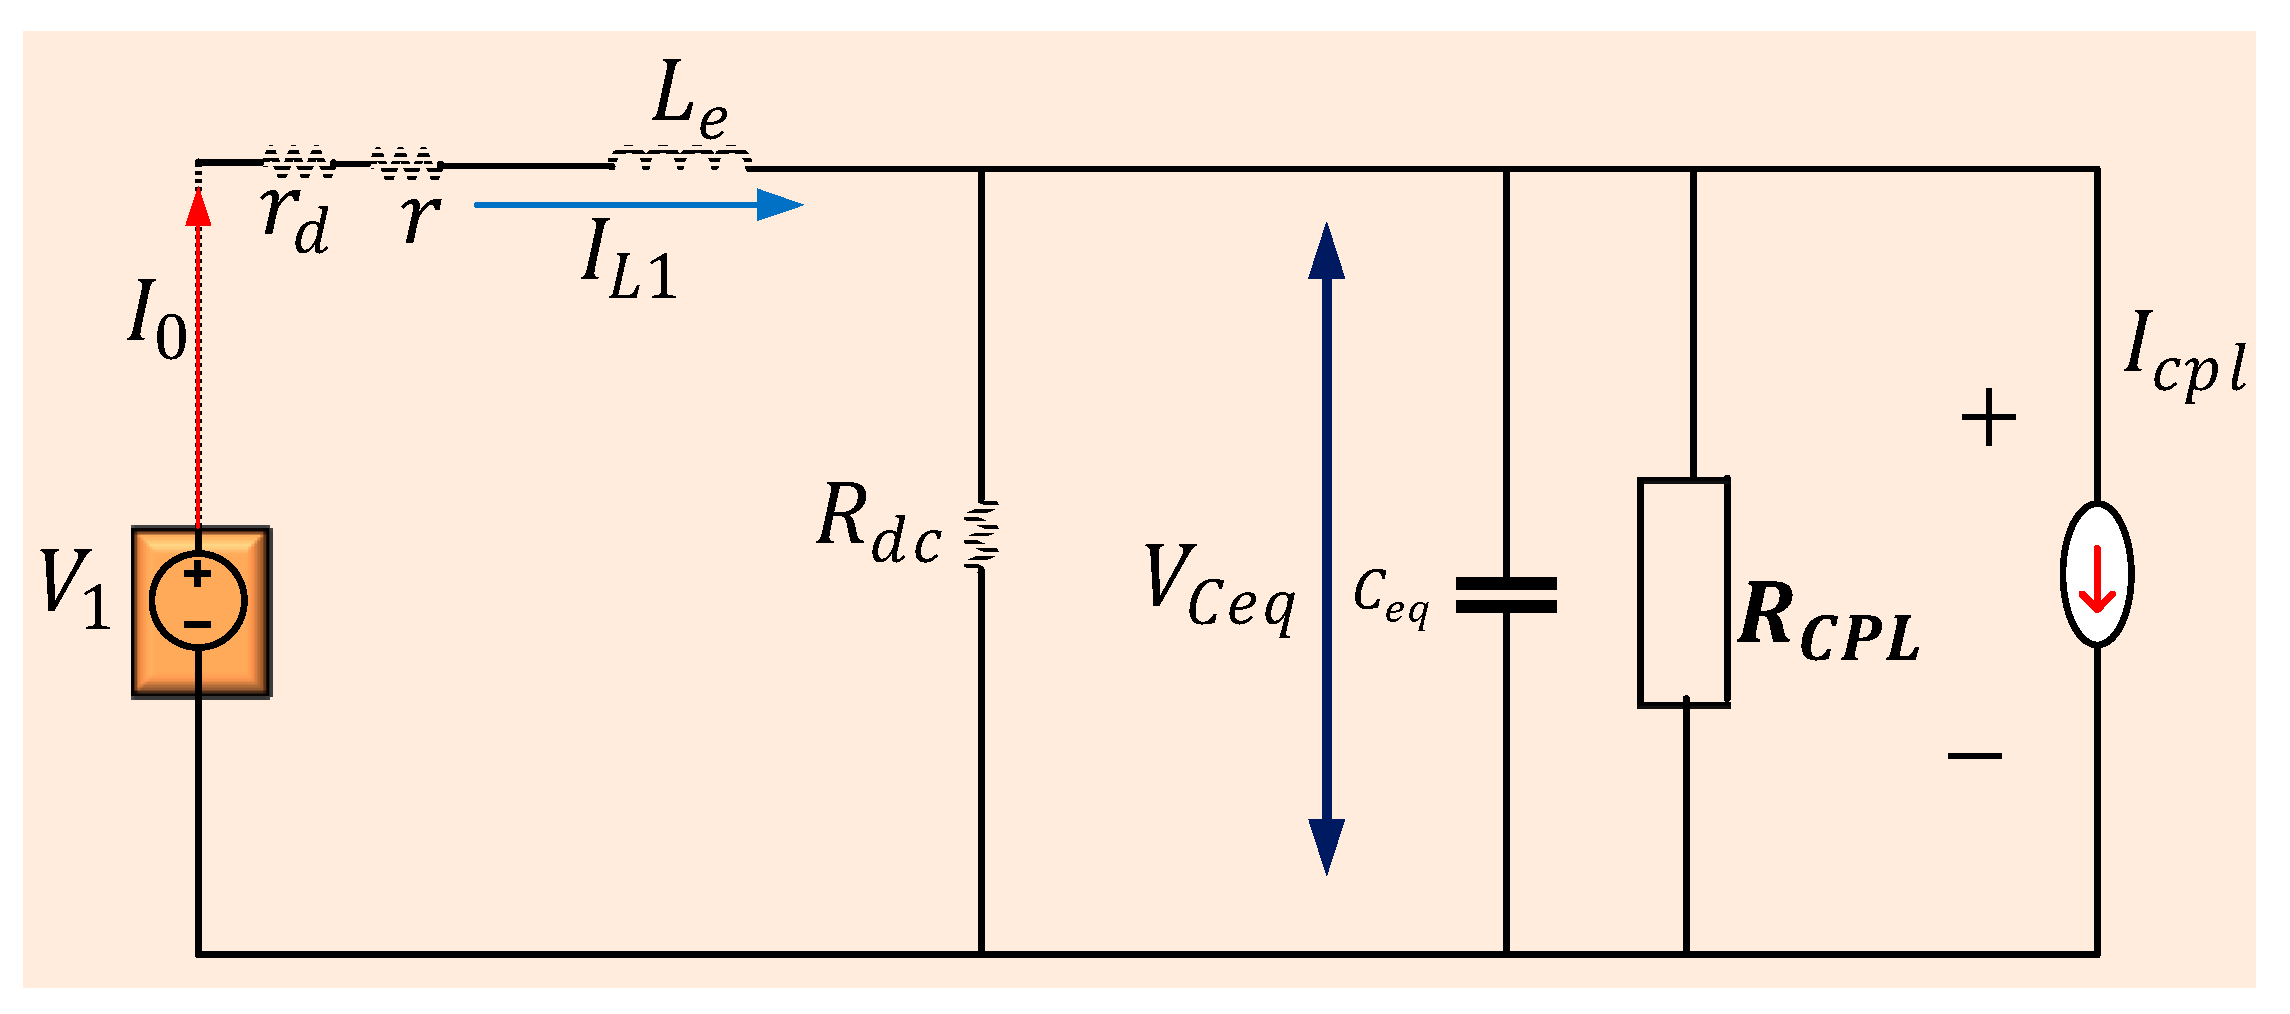
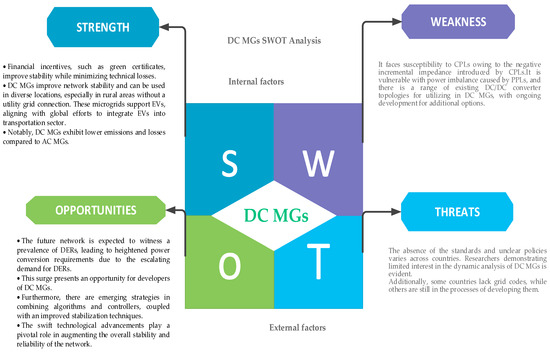
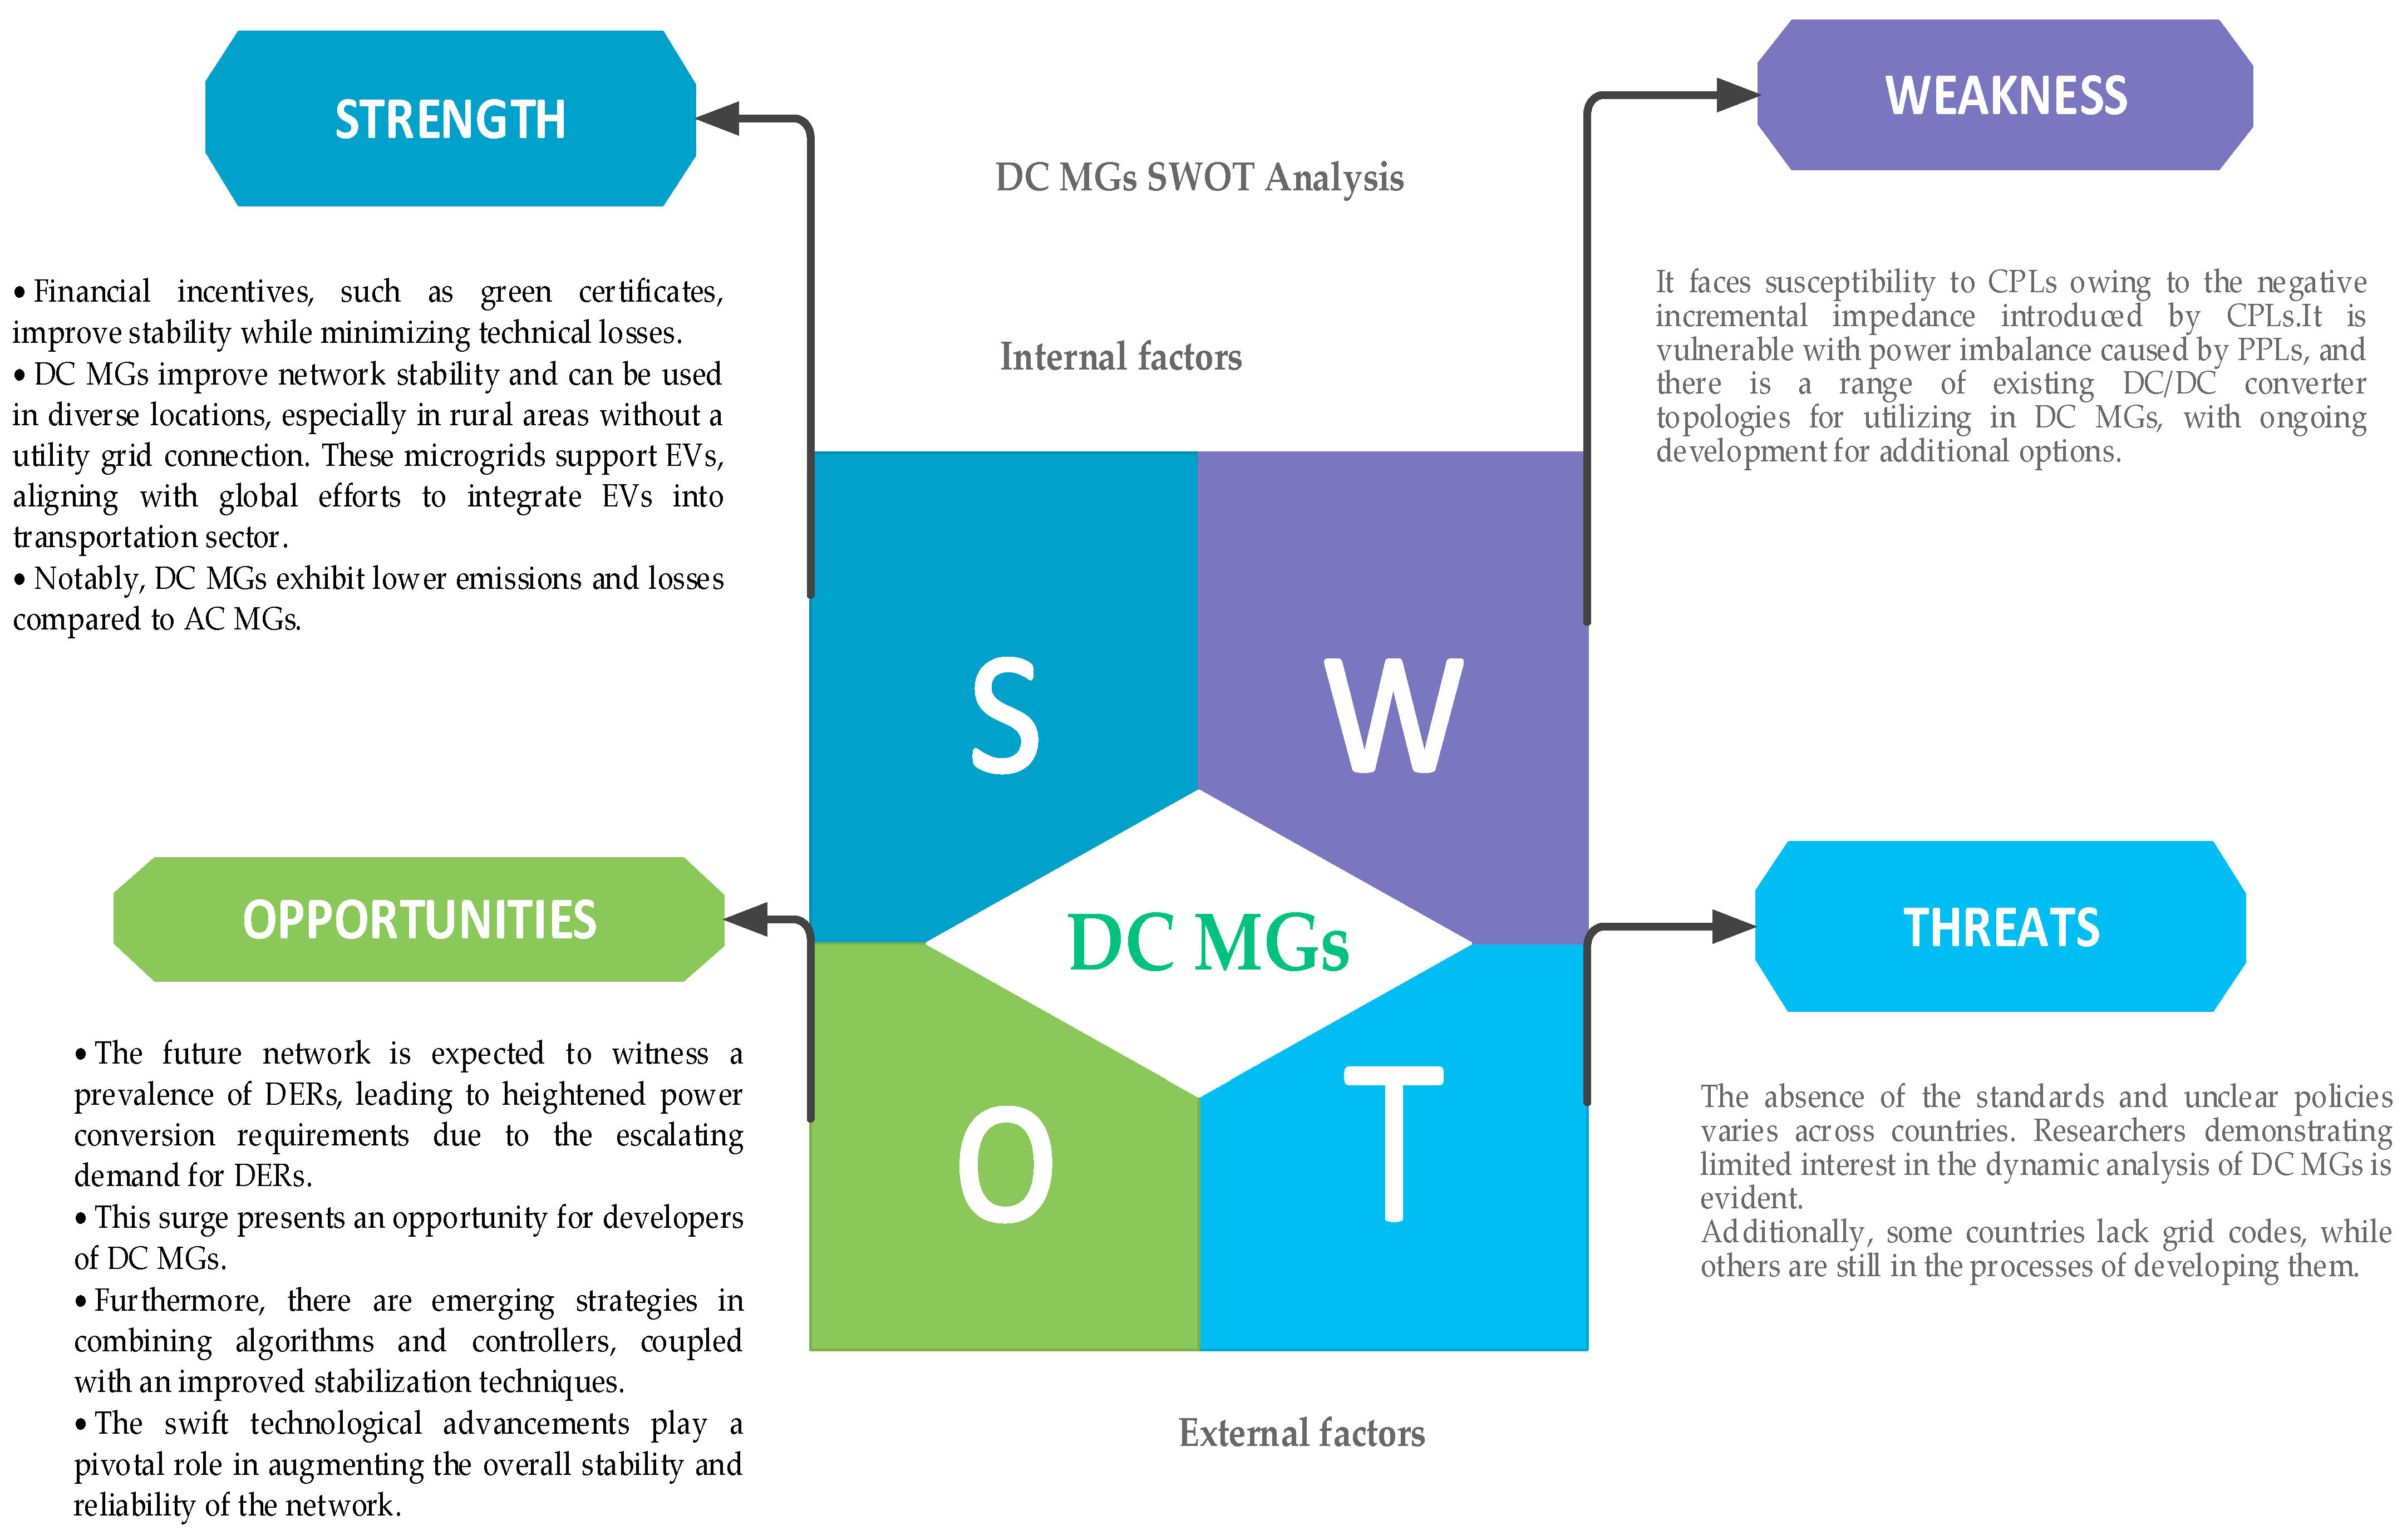

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2024 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).