Article

Design and Analysis of Second-Order Sliding Mode Controller for Active Magnetic Bearing

School of Electrical Engineering and Information, Tianjin University, No. 92 Weijin Road, Tianjin 300072, China
*
Author to whom correspondence should be addressed.
Energies 2020, 13(22), 5965; https://doi.org/10.3390/en13225965
Submission received: 19 October 2020 / Revised: 11 November 2020 / Accepted: 14 November 2020 / Published: 16 November 2020
(This article belongs to the Special Issue Advanced Electric Vehicle Techniques)

Abstract

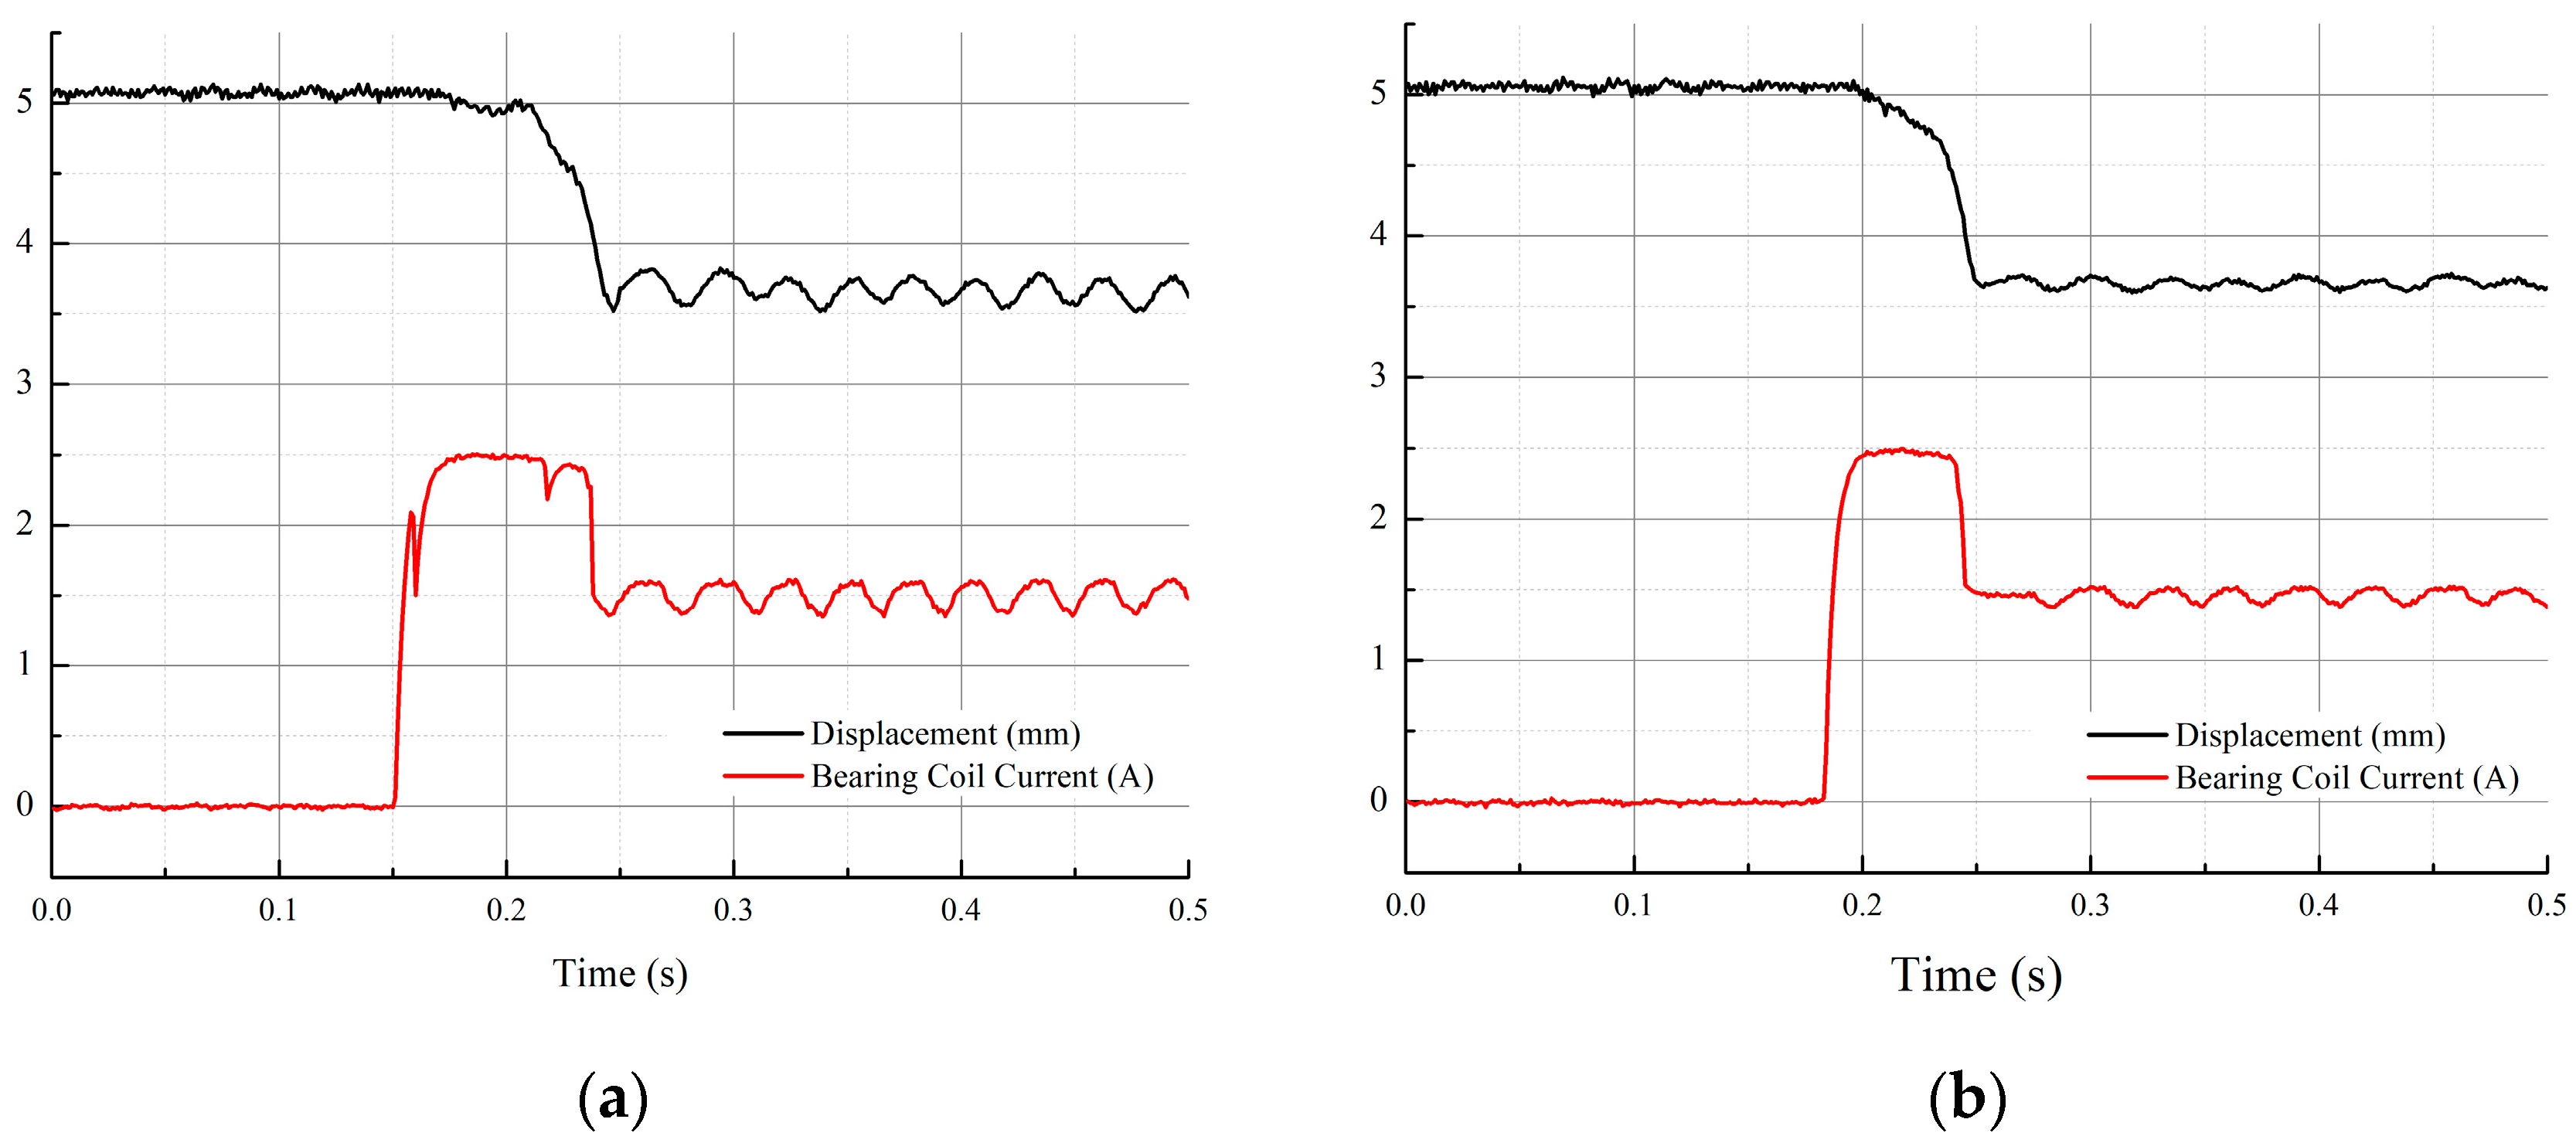
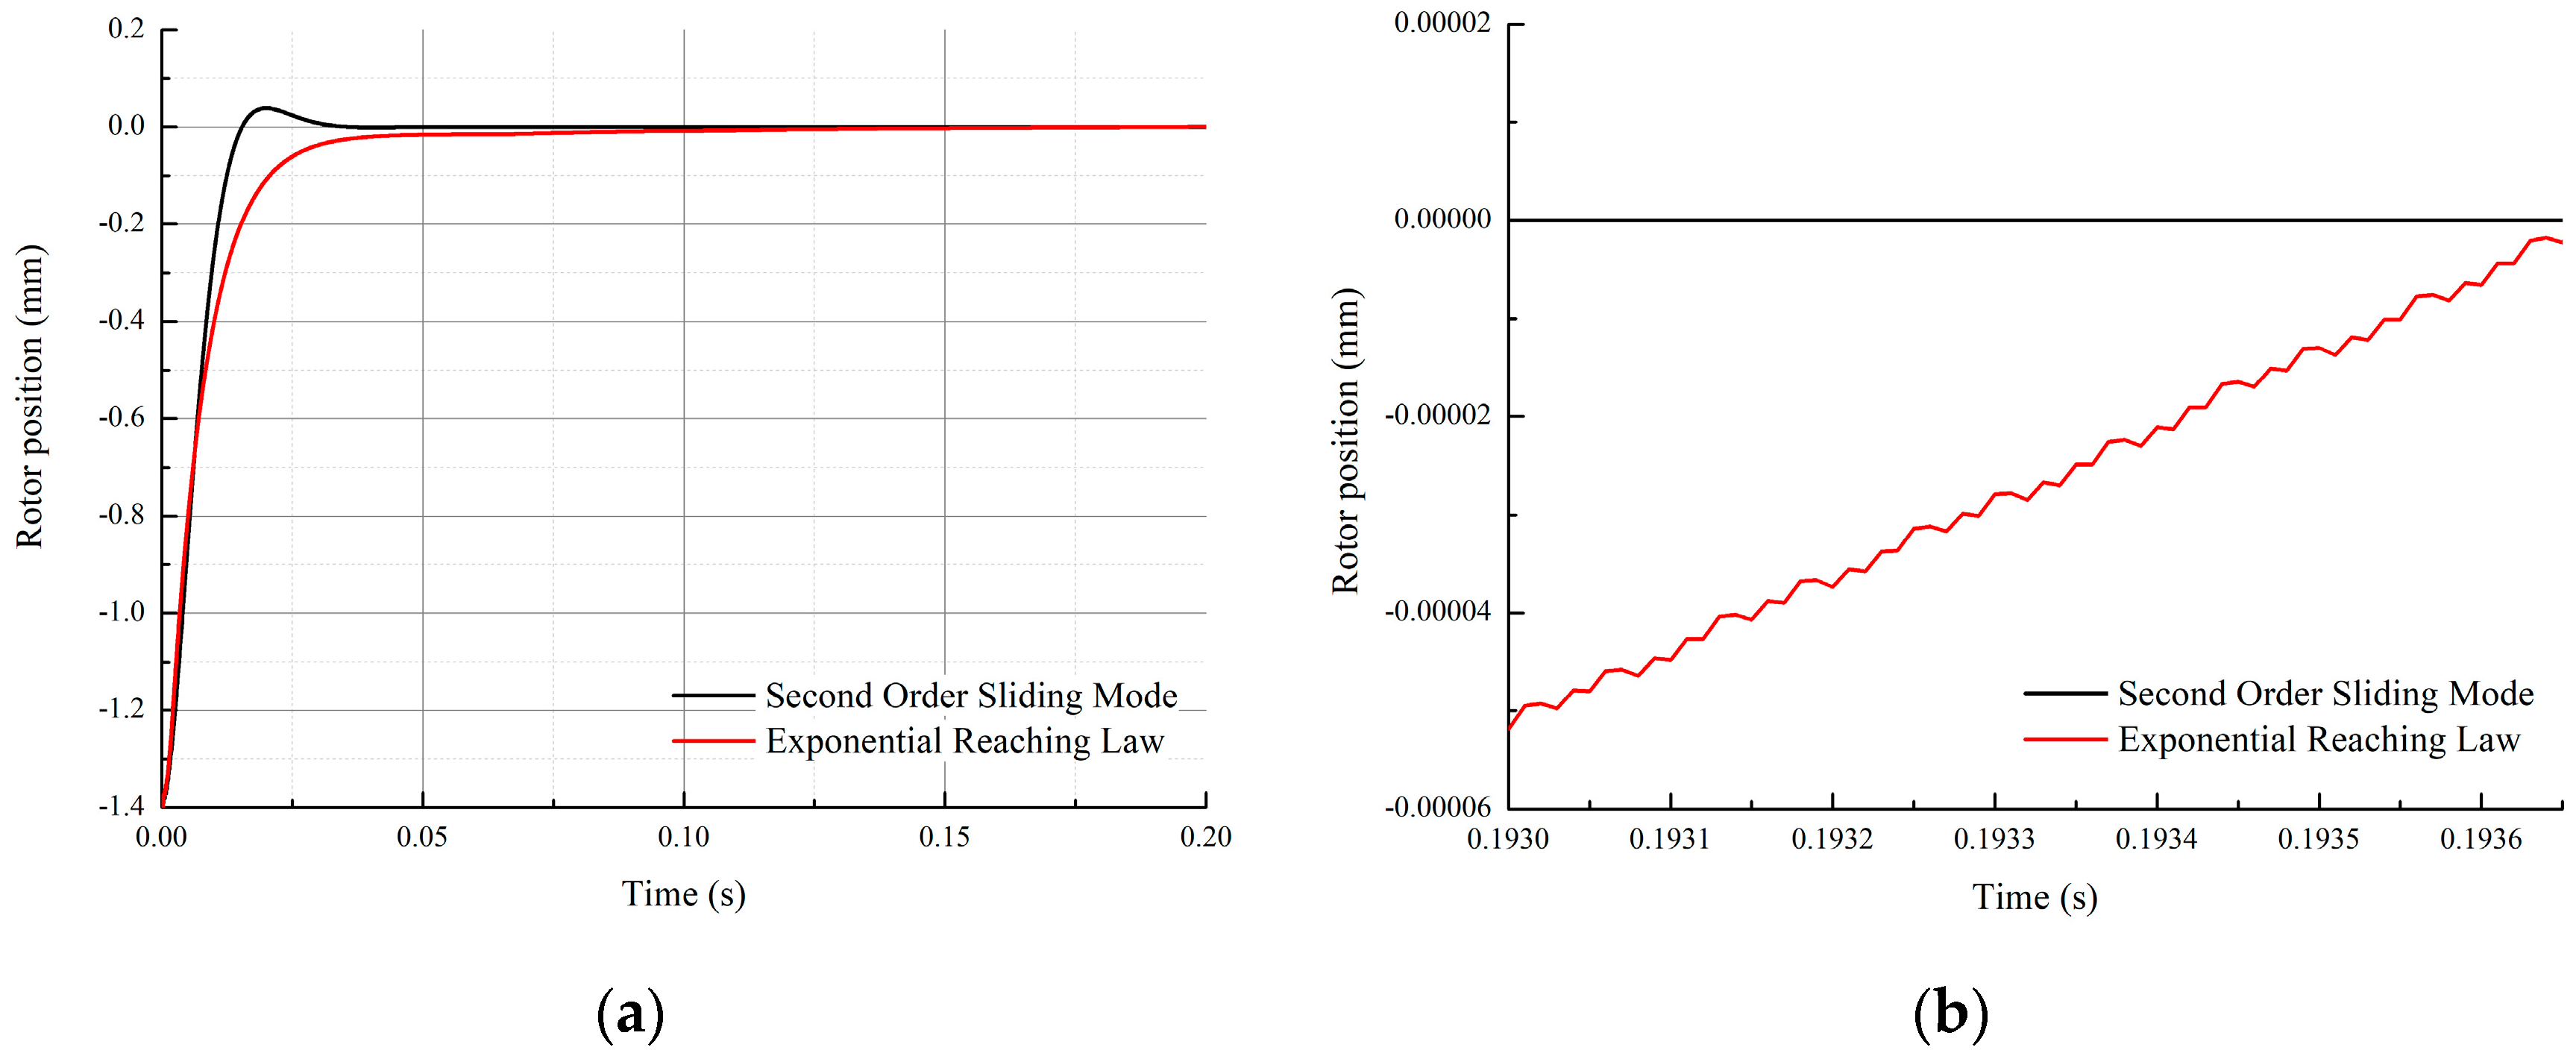
An active magnetic bearing (AMB) is a kind of high-performance bearing that uses controllable electromagnetic force to levitate the rotor. Its control performance directly affects the operation characteristics of high-speed motors and other electromechanical products. The magnetic bearing control model is nonlinear and difficult to control. Sliding mode control algorithm can be used in the magnetic bearing control system, but the traditional sliding mode control has the problem of high-frequency chattering, which affects the operation stability of magnetic bearings. Based on the second-order sliding mode control algorithm, a new second-order sliding mode controller for active magnetic bearing control was designed, and the stability of the designed sliding mode control law was proven by Lyapunov criterion. On the basis of the established active magnetic bearing control model, the numerical analysis of the designed controller was carried out, and the control effect was compared with that obtained by the exponential reaching law for the sliding mode control algorithm. The experimental results show that the designed sliding mode controller has better dynamic performance and stability than the exponential reaching law for the sliding mode controller.
Keywords: active magnetic bearing; second-order sliding mode; chattering problem; control active magnetic bearing; second-order sliding mode; chattering problem; control