Article

Enhancing Off-Road Topography Estimation by Fusing LIDAR and Stereo Camera Data with Interpolated Ground Plane


Engineering Design, KTH Royal Institute of Technology, SE-100 44 Stockholm, Sweden
*
Authors to whom correspondence should be addressed.
Sensors 2025, 25(2), 509; https://doi.org/10.3390/s25020509
Submission received: 1 November 2024 / Revised: 17 December 2024 / Accepted: 27 December 2024 / Published: 16 January 2025

Abstract

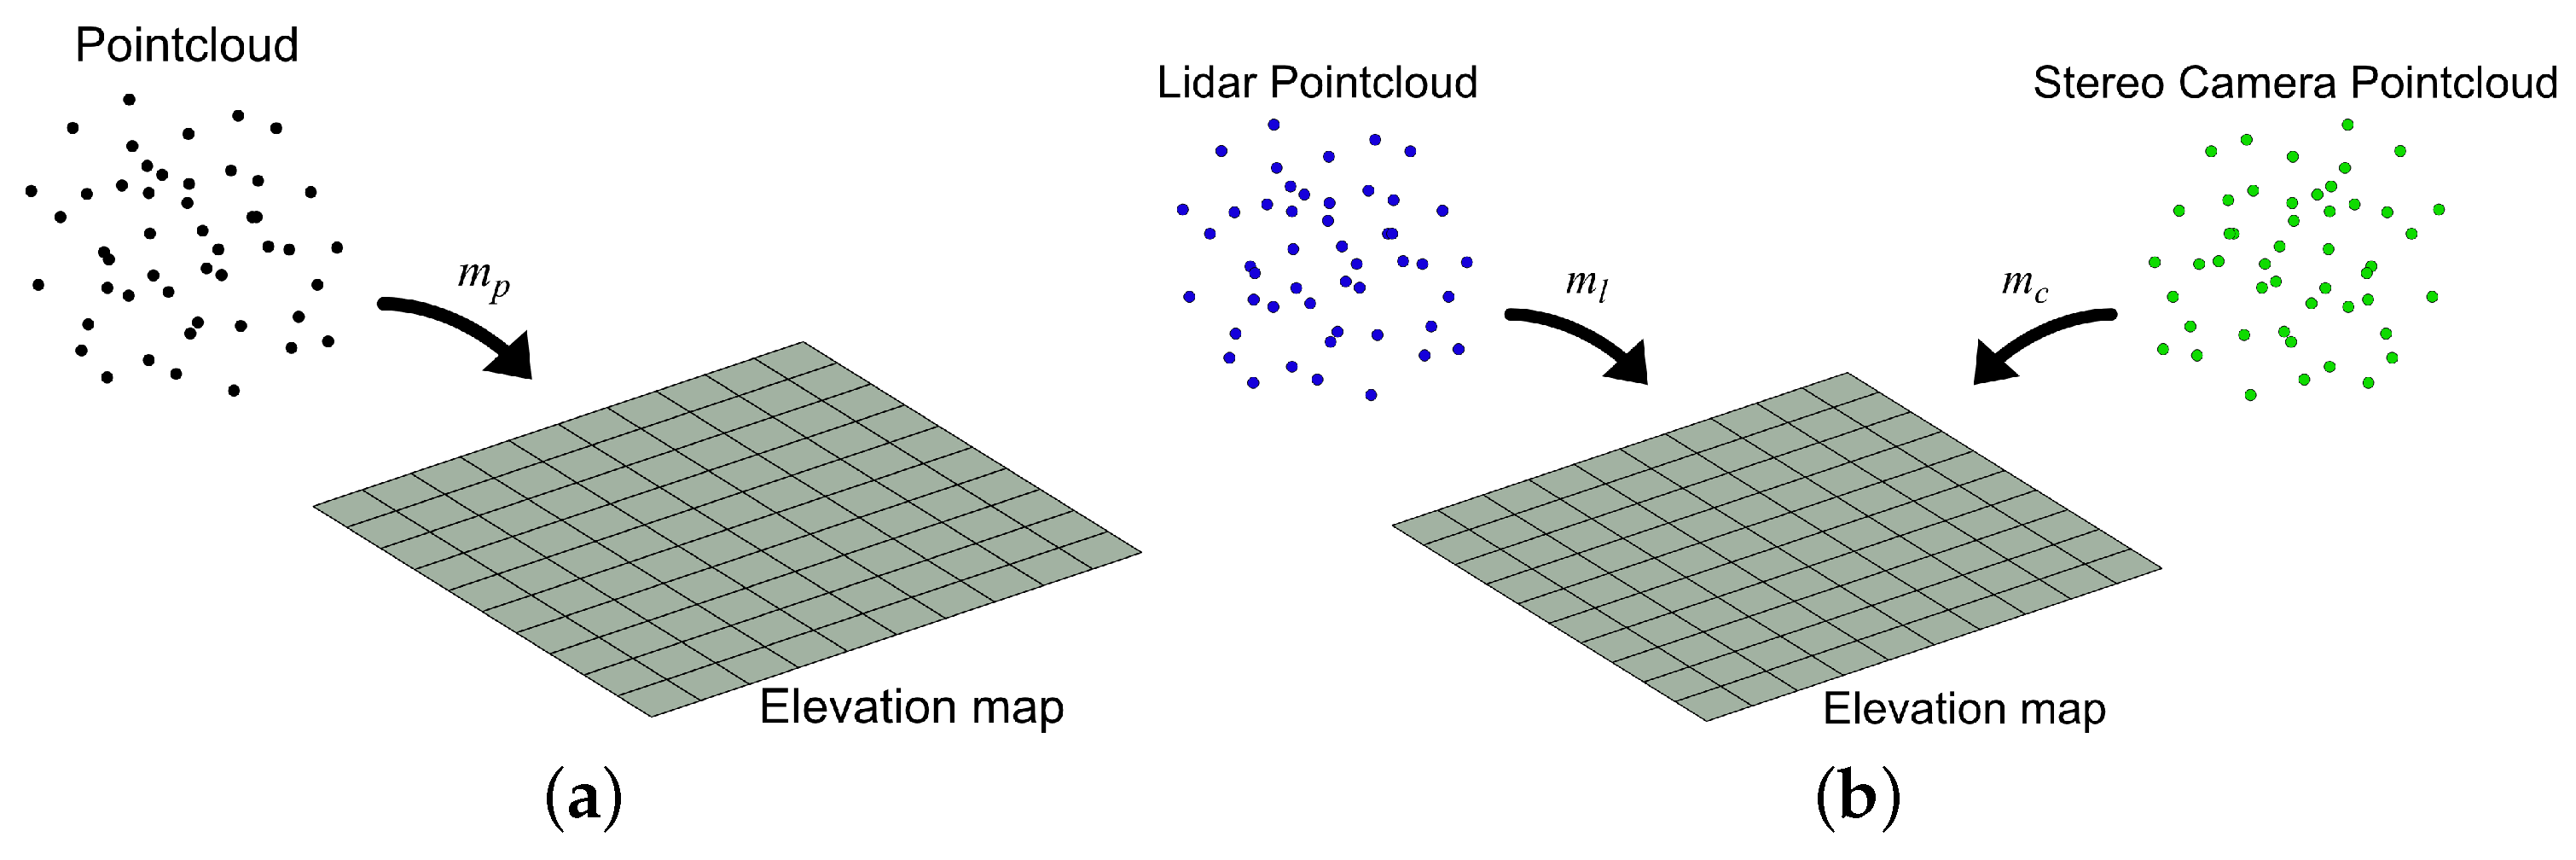
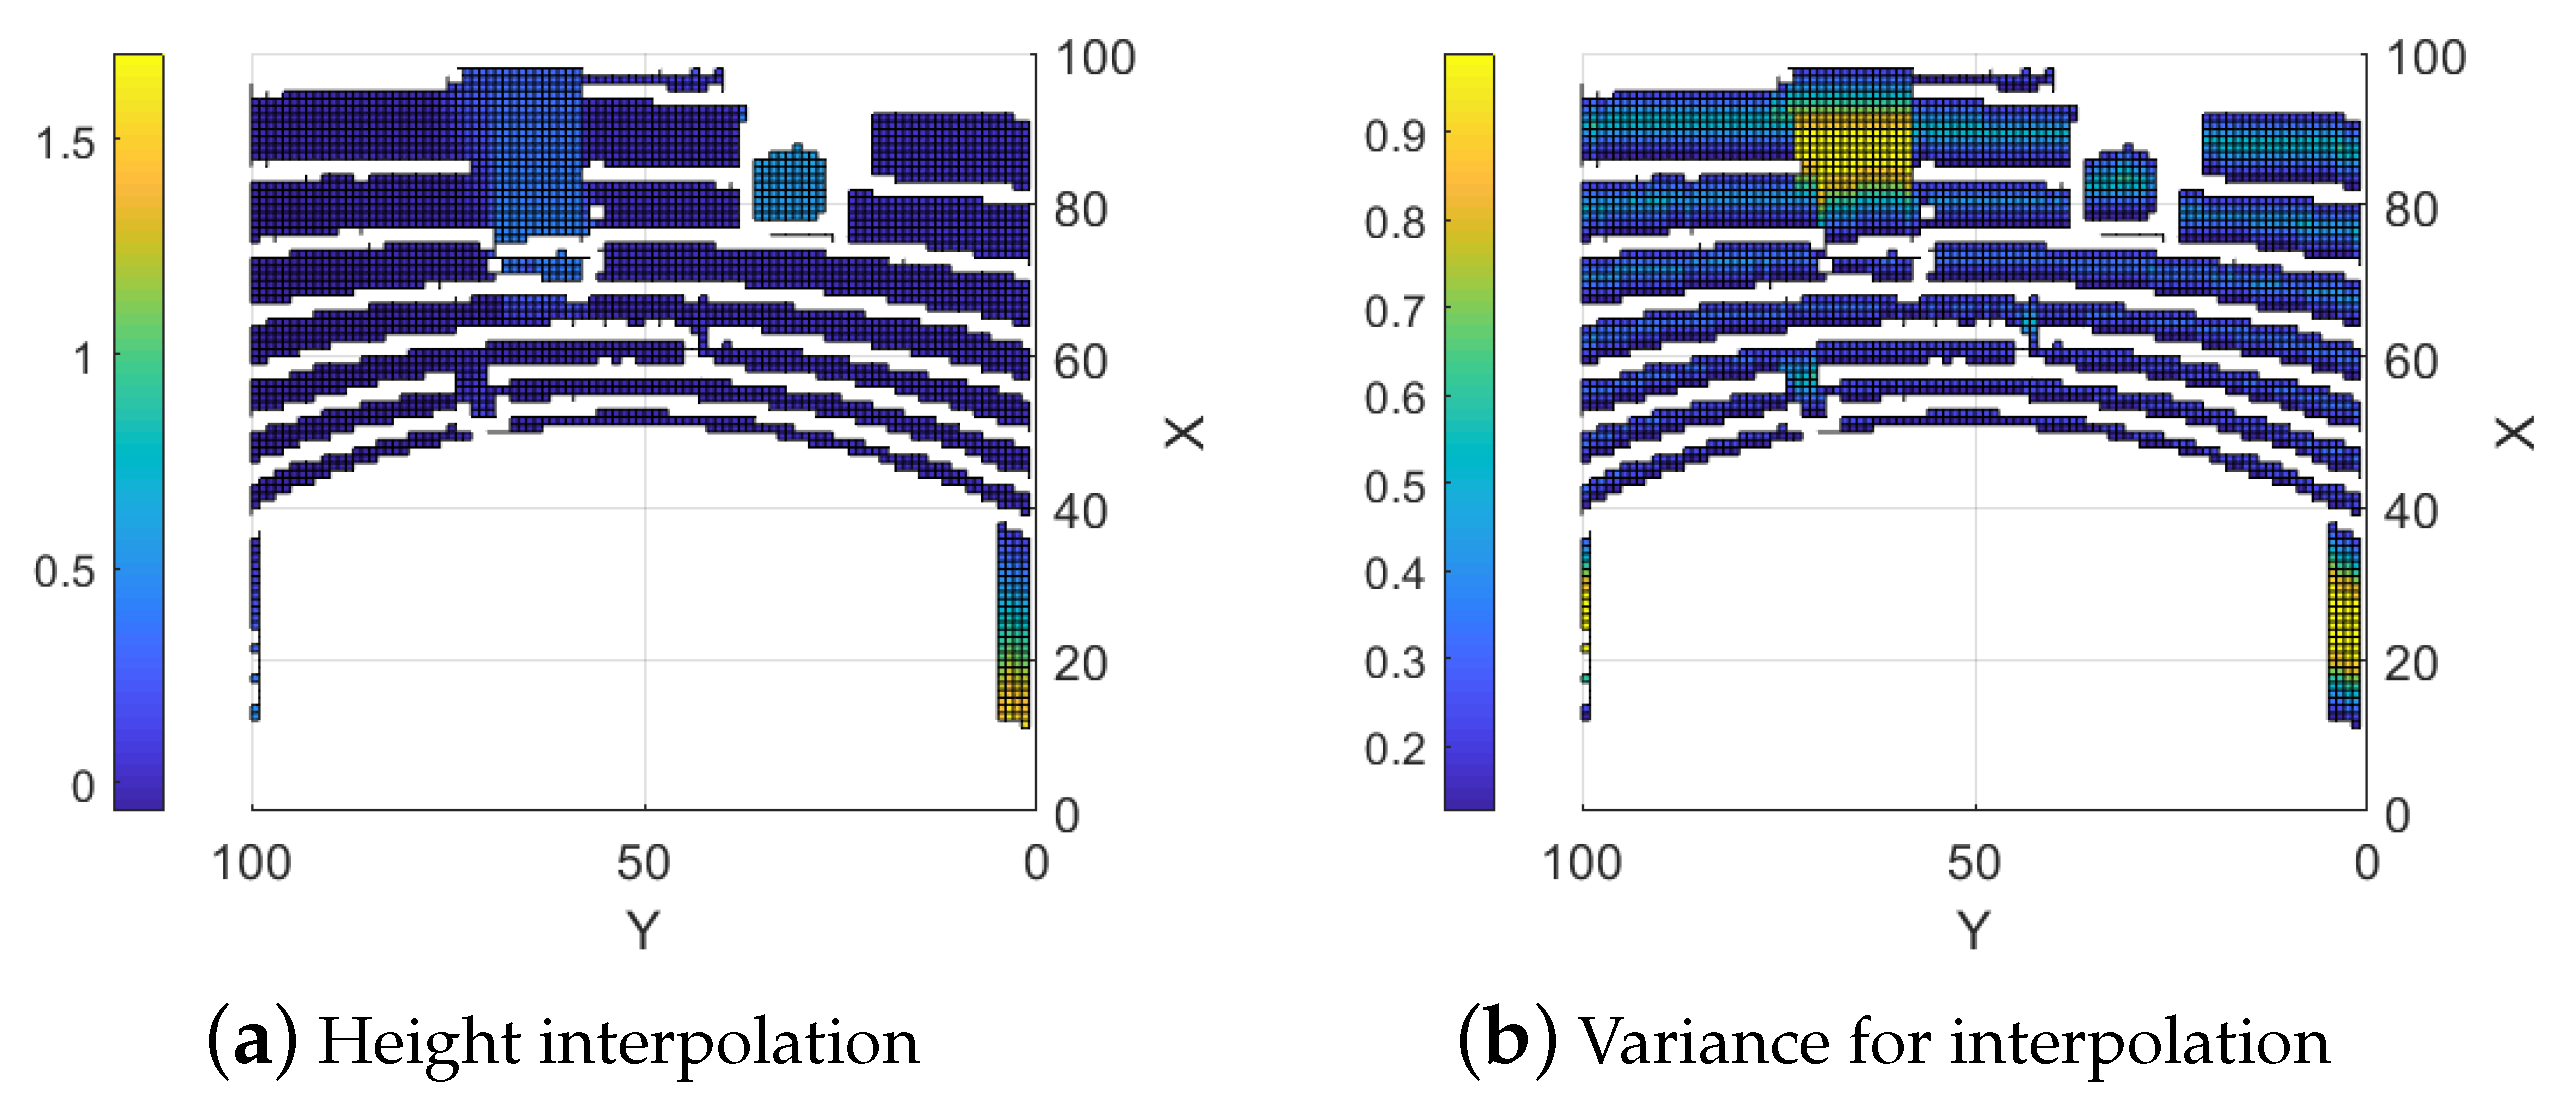
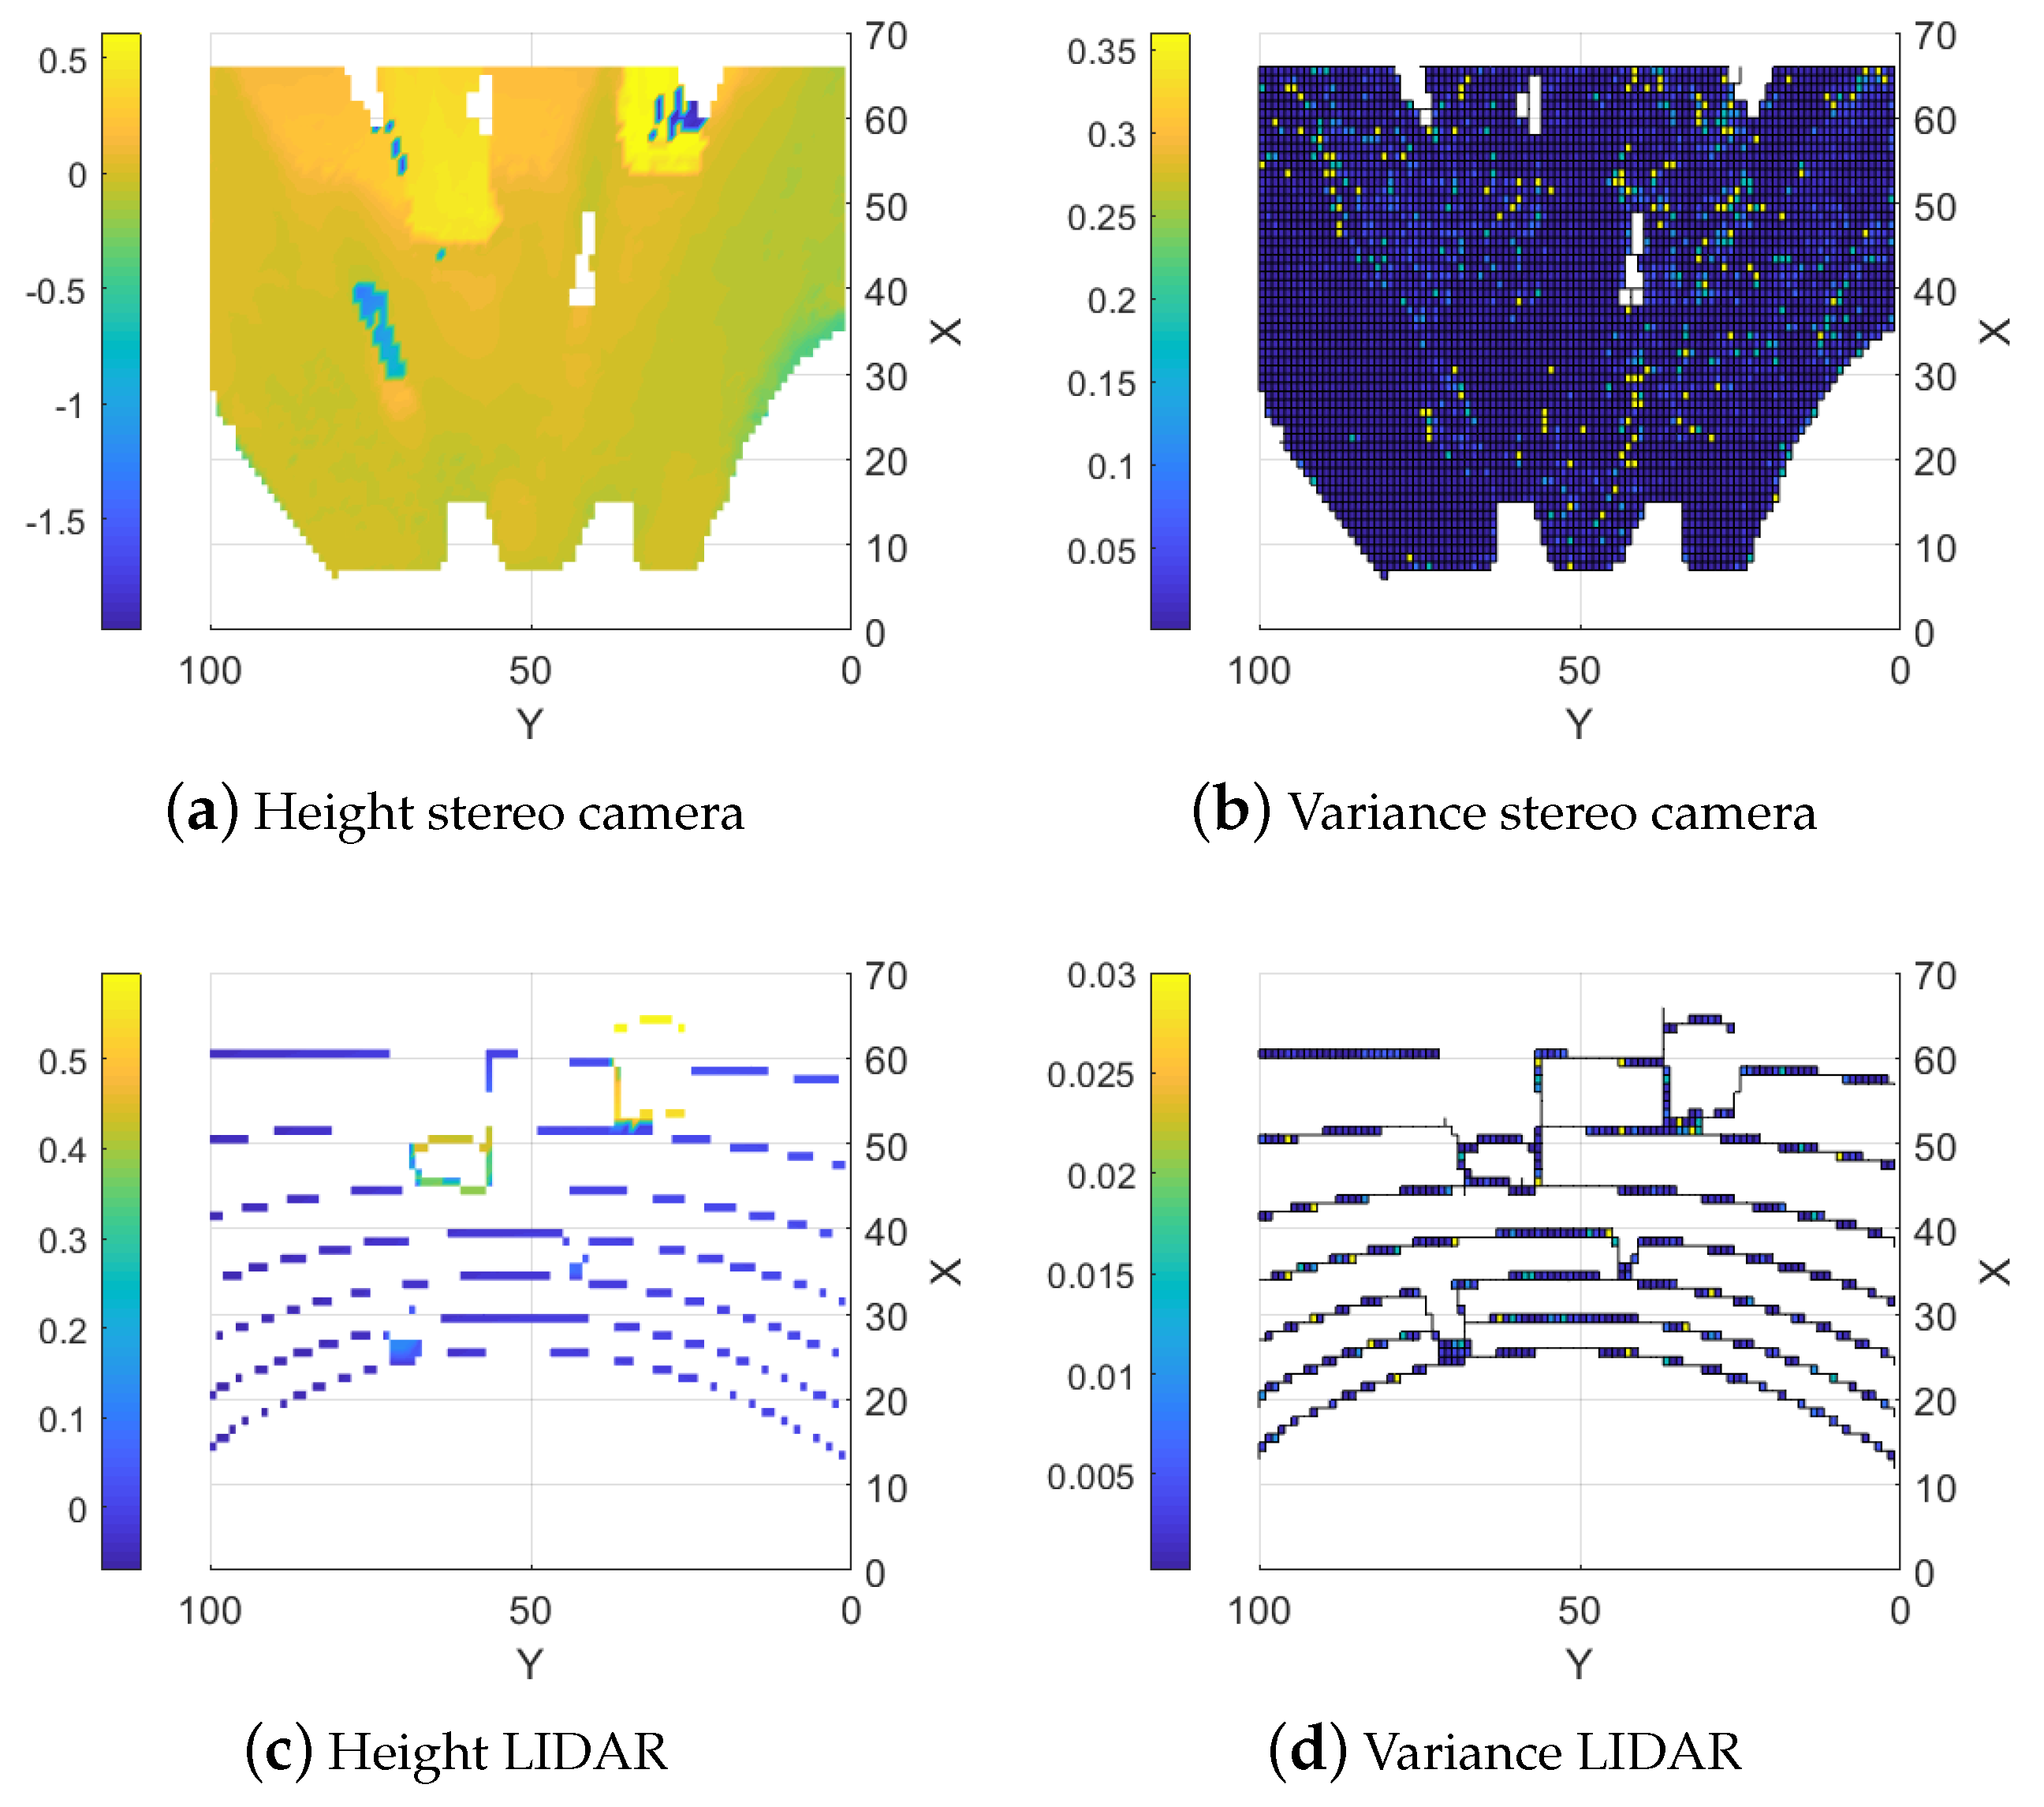
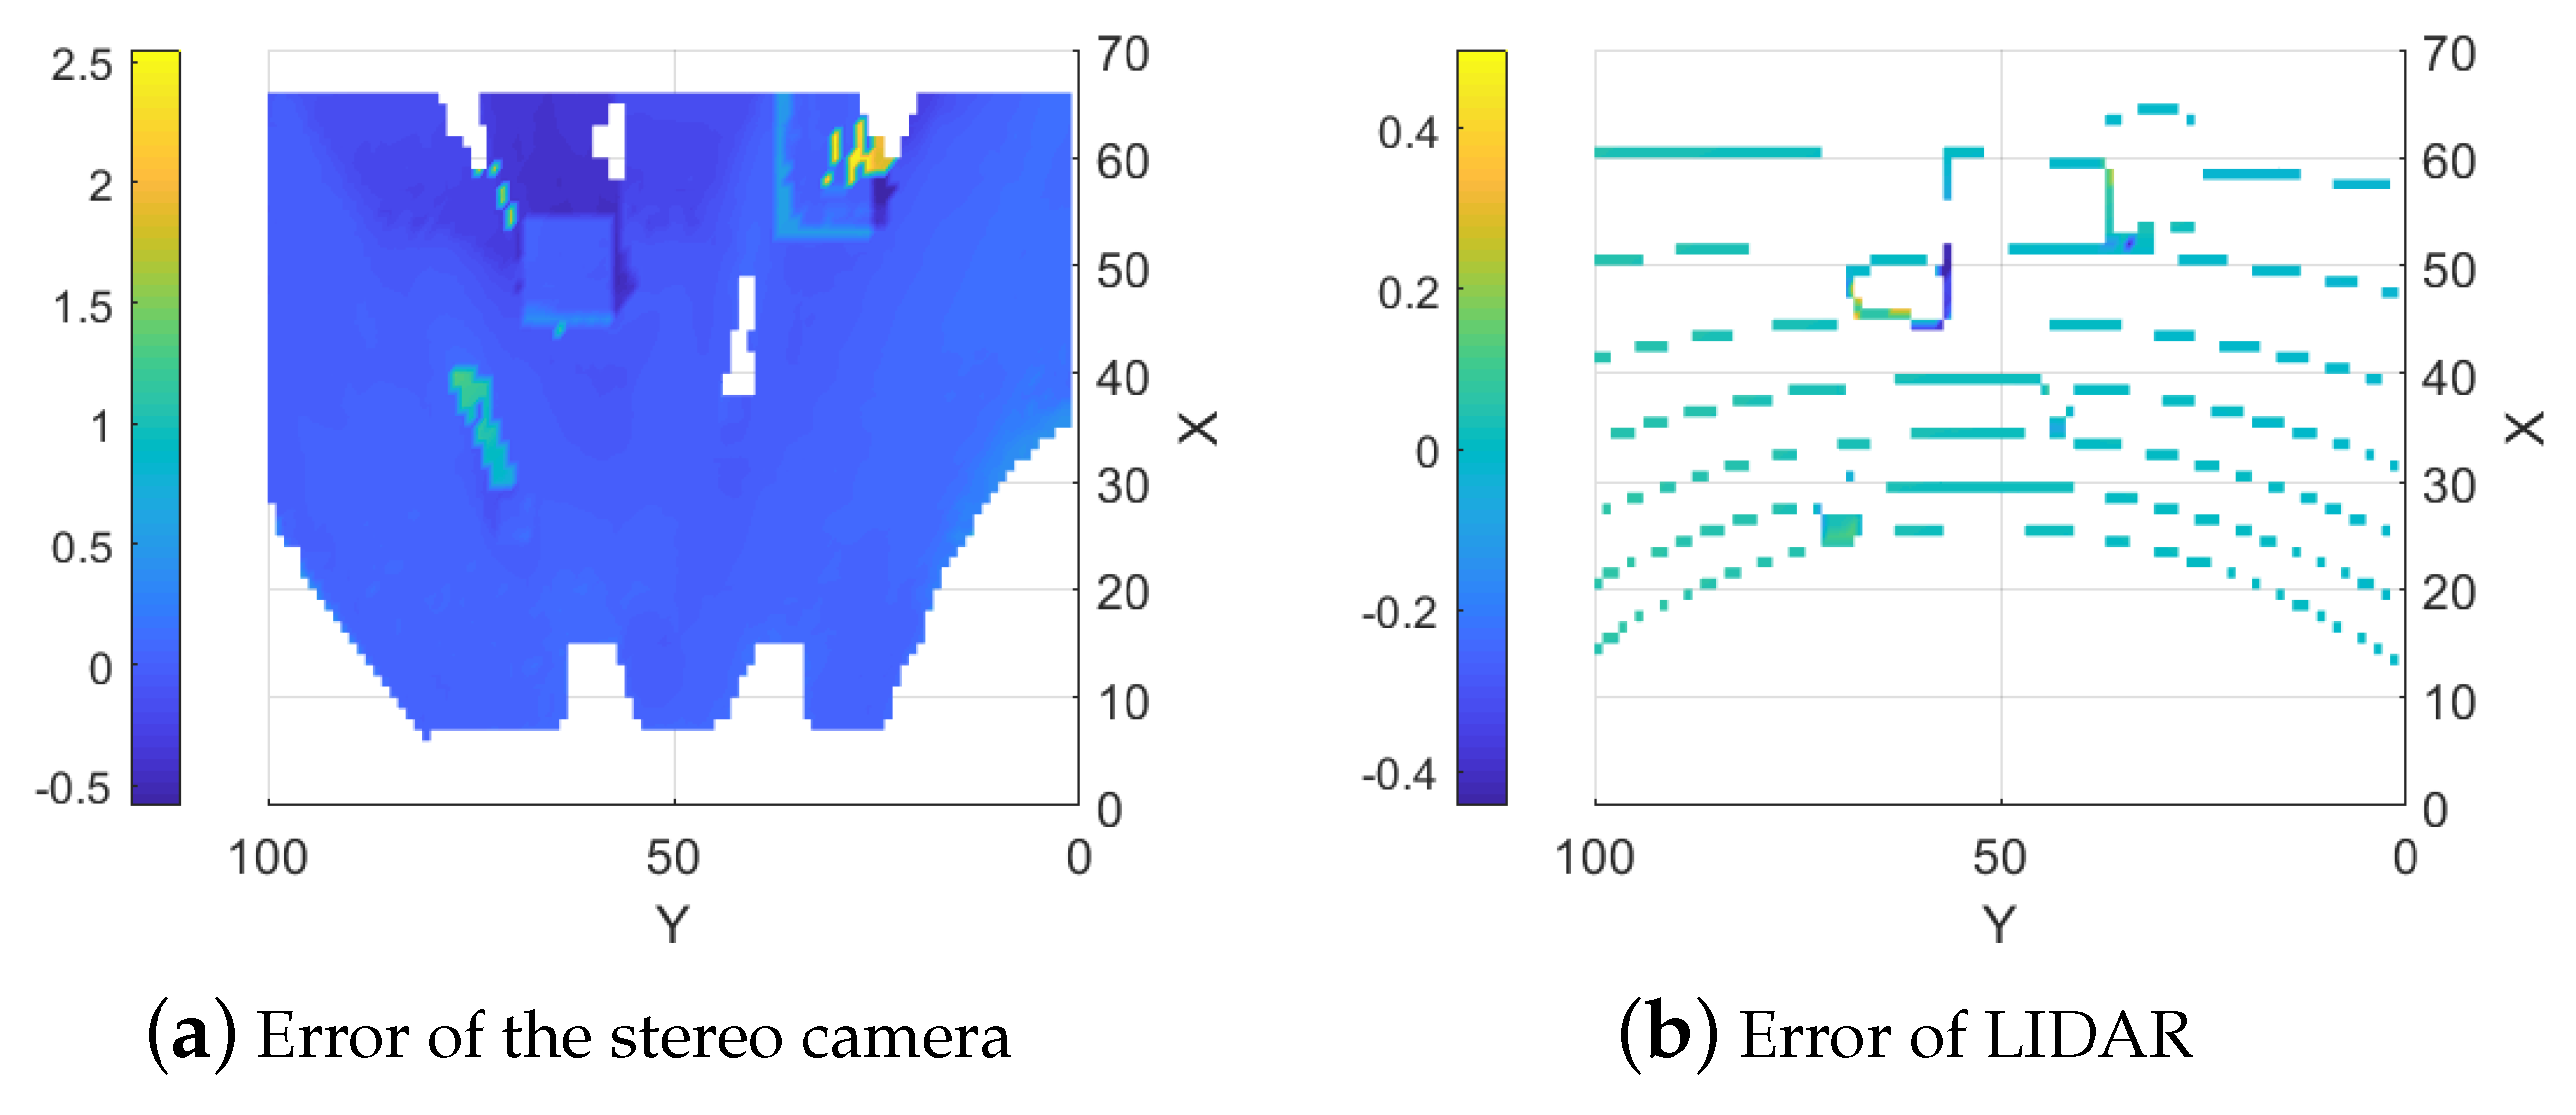
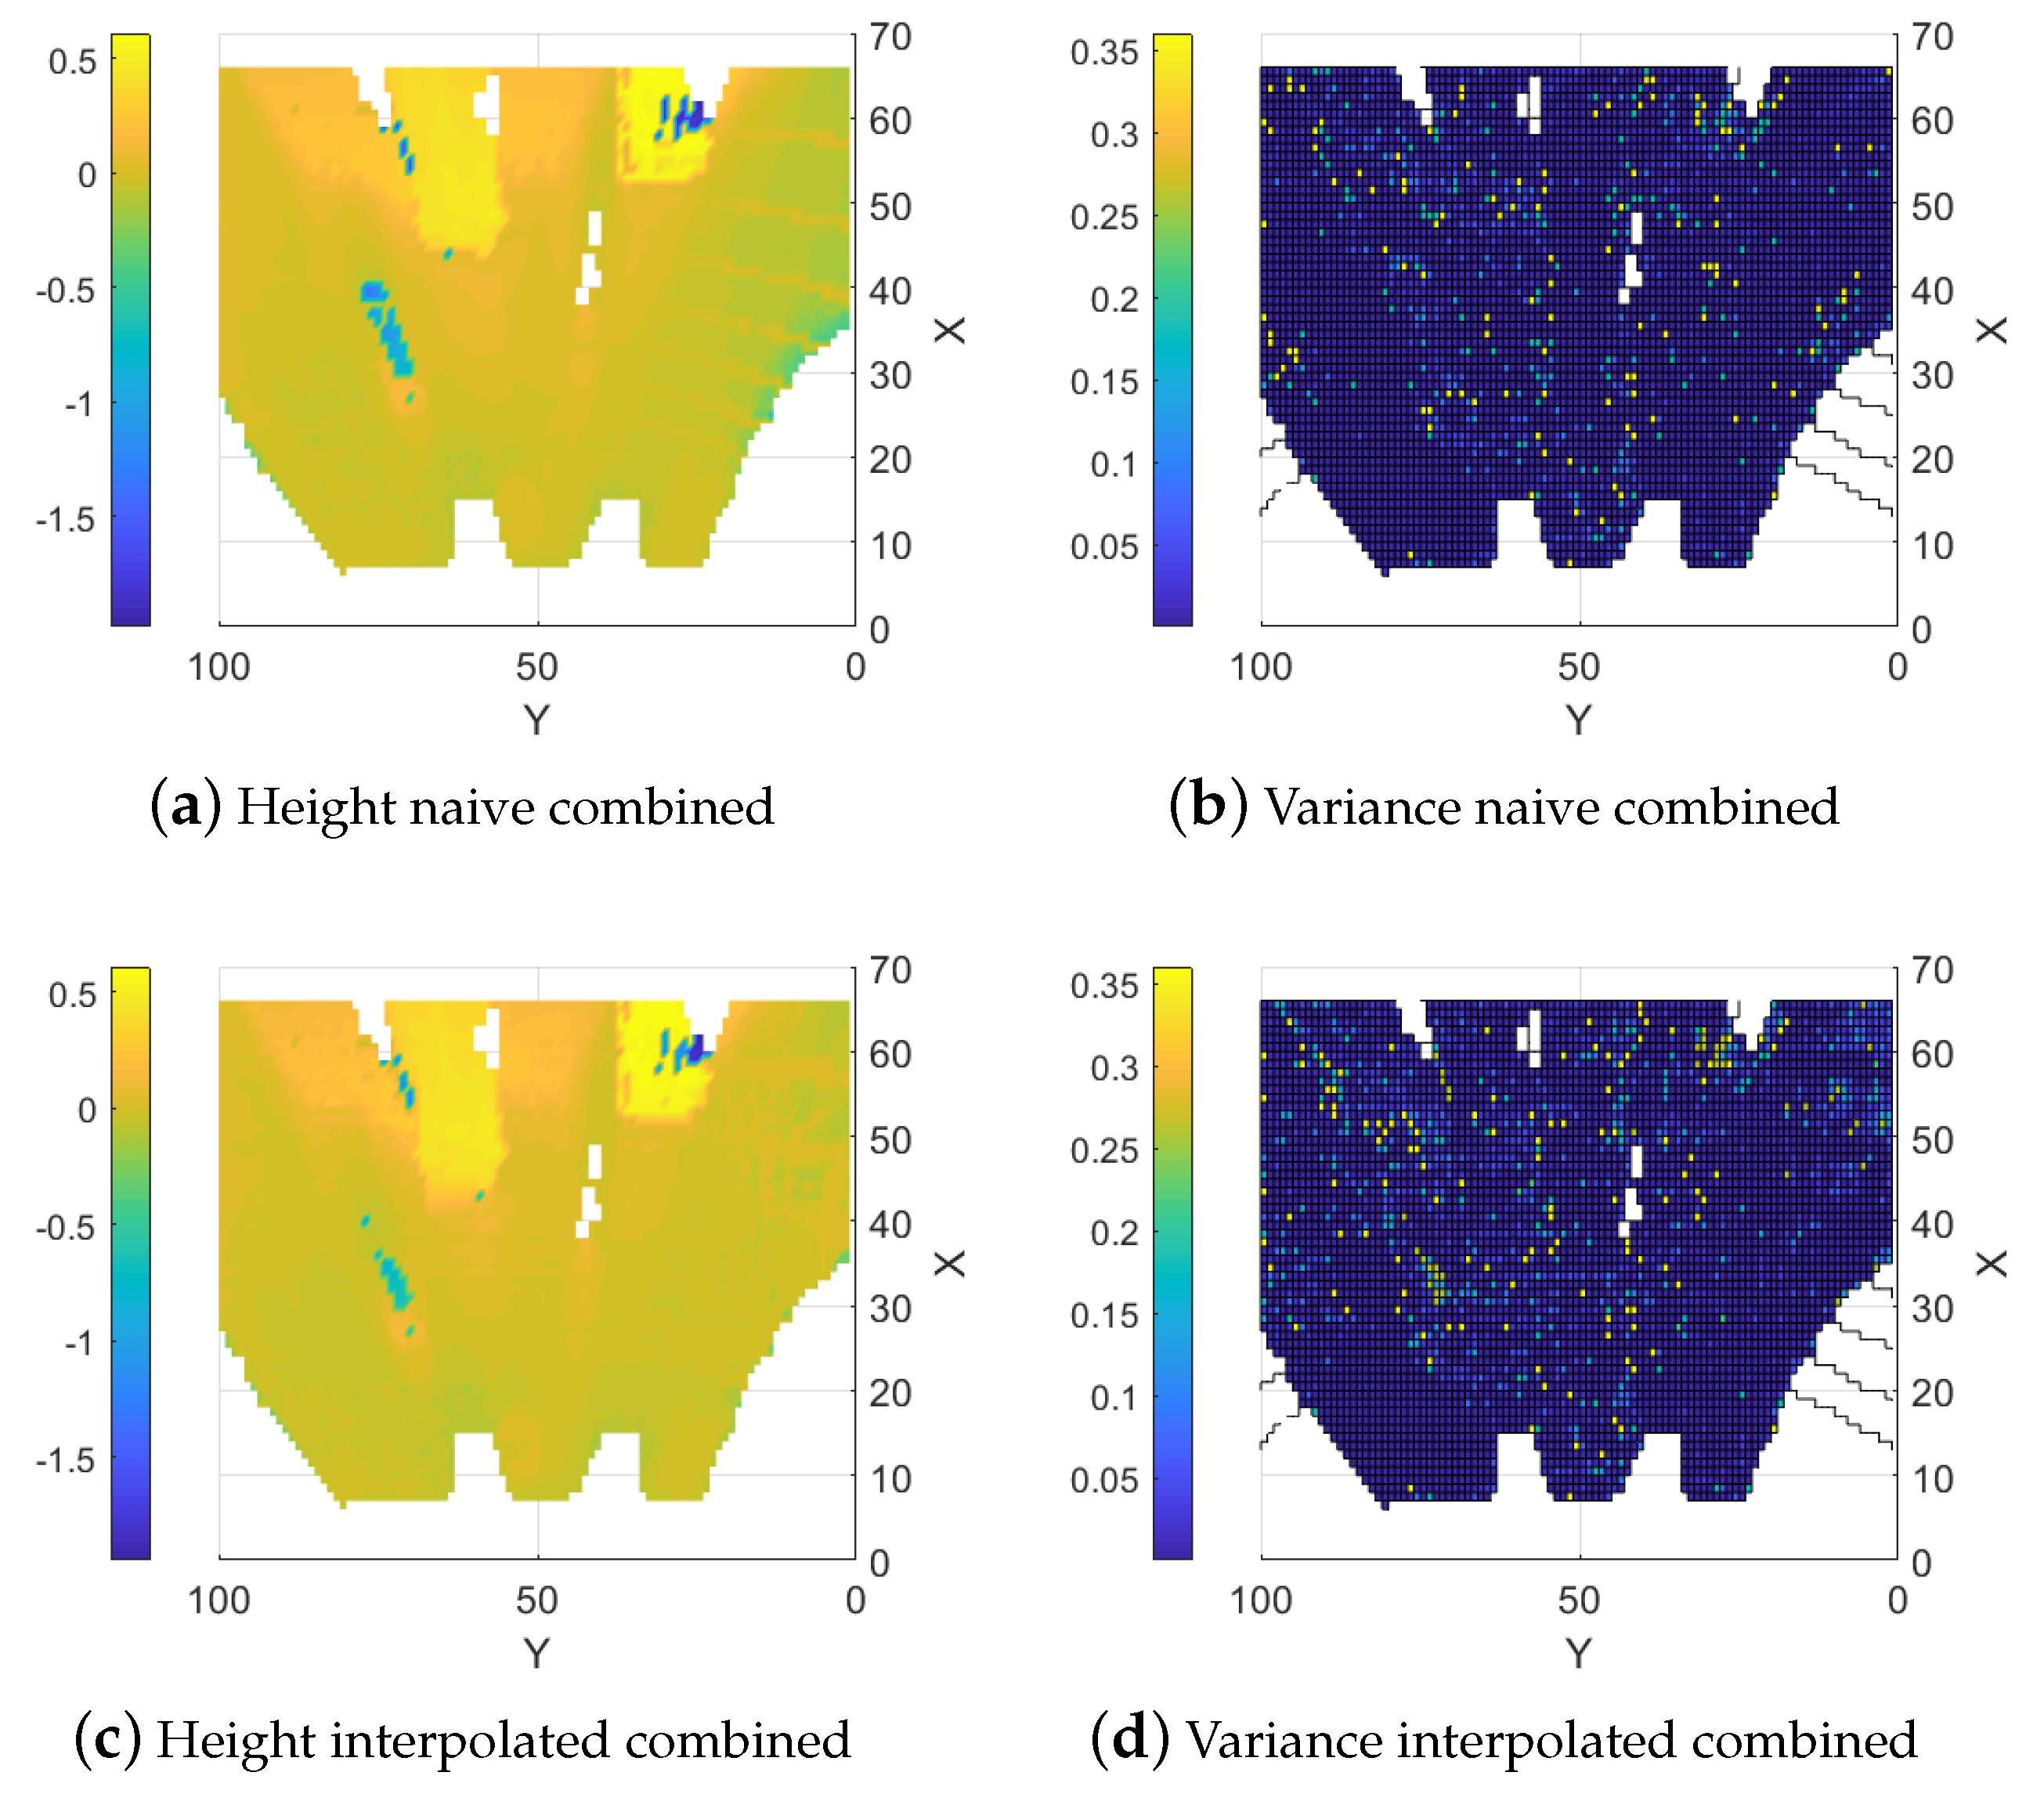
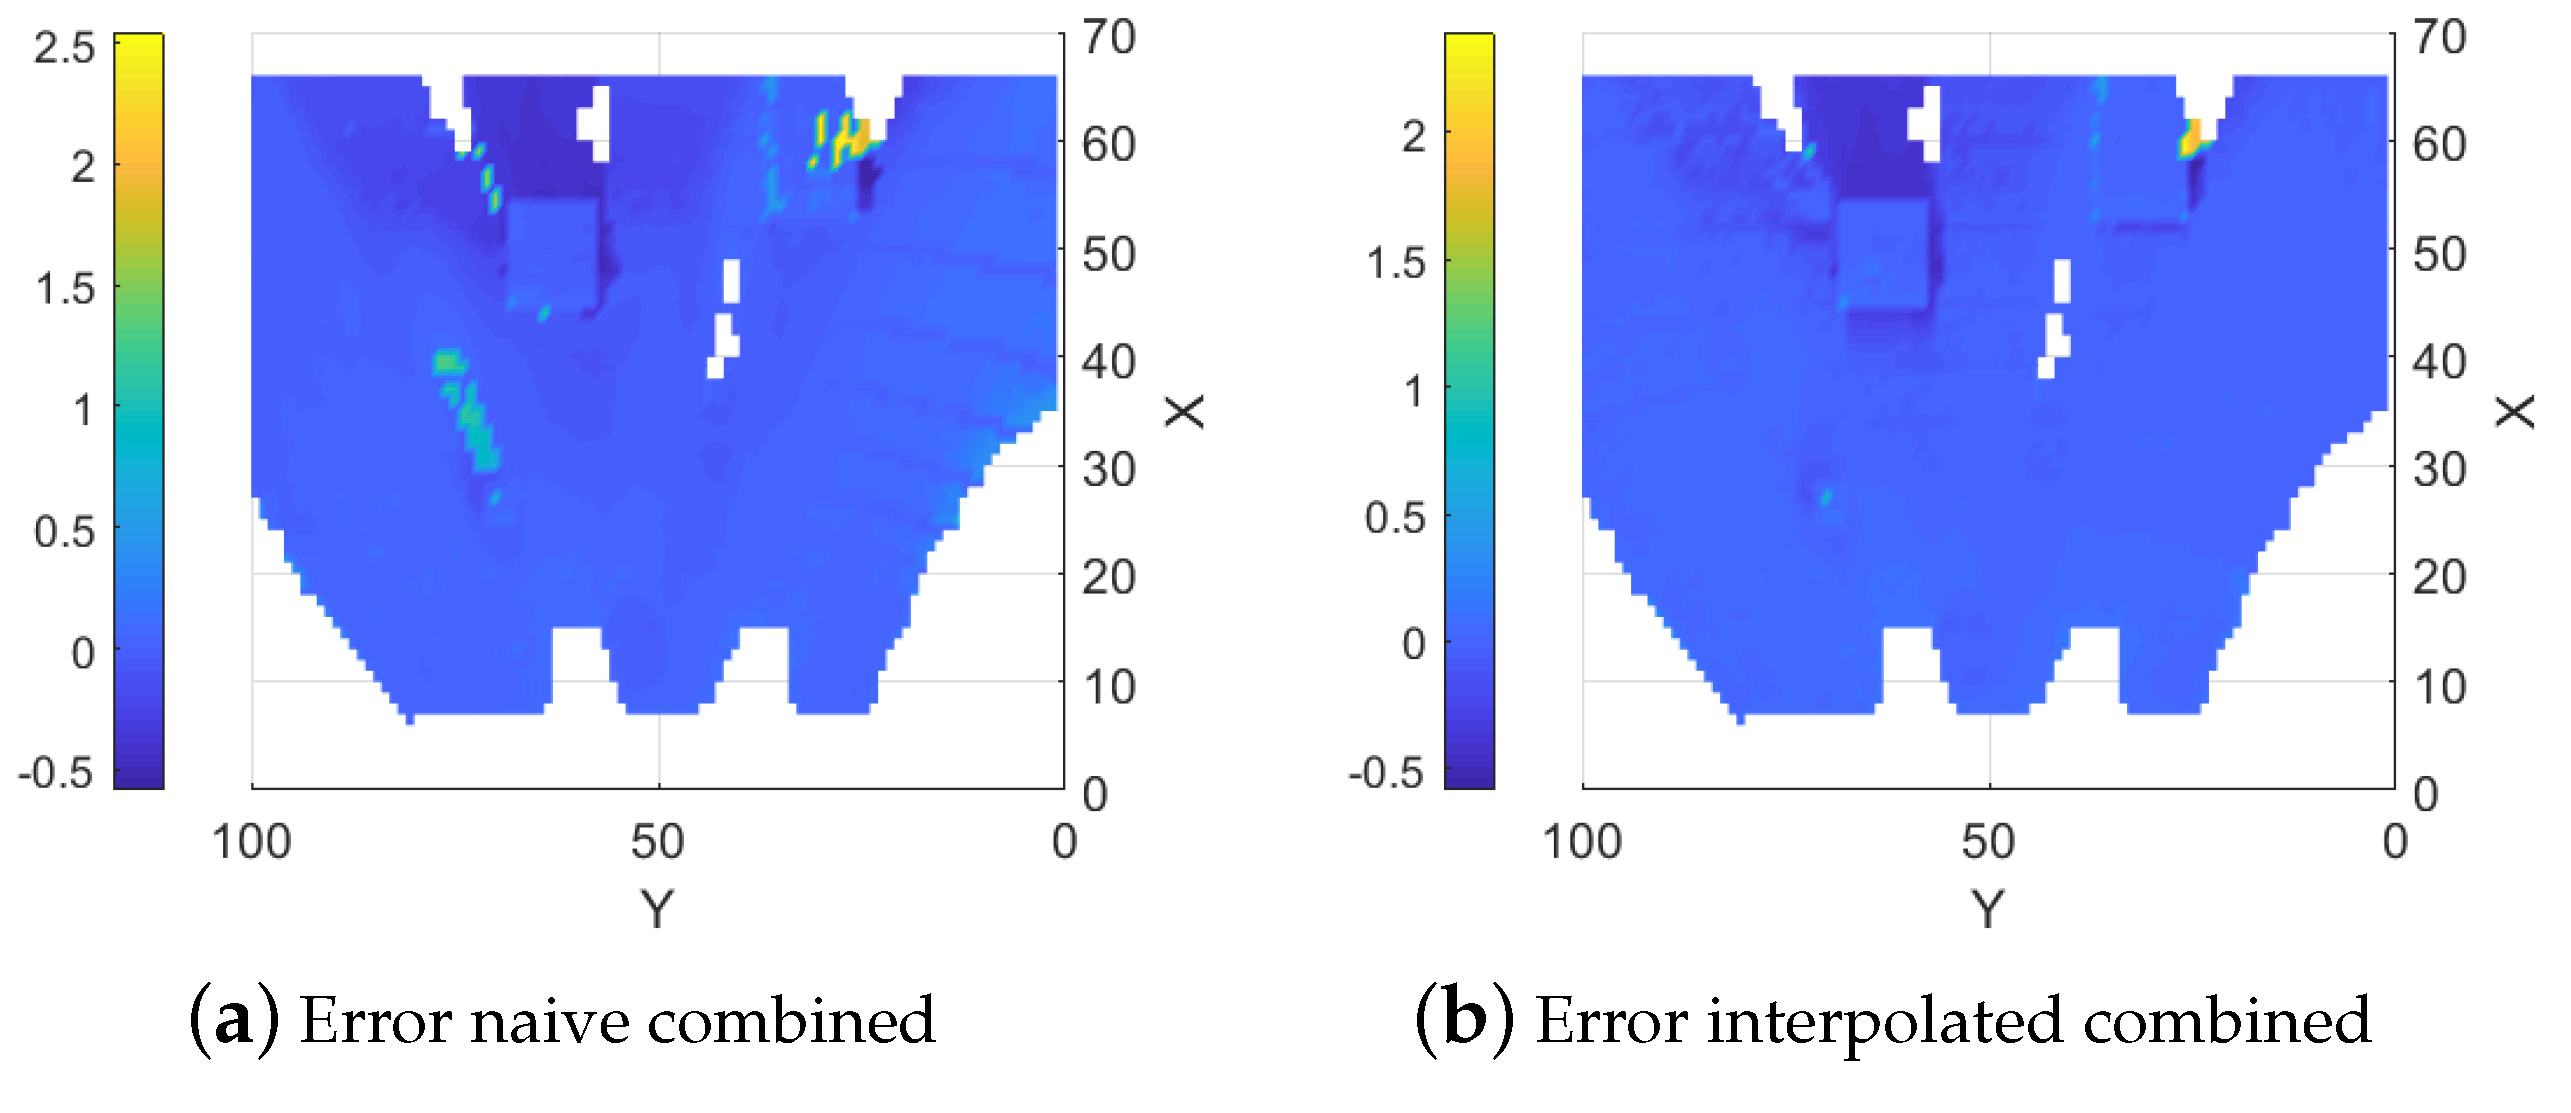
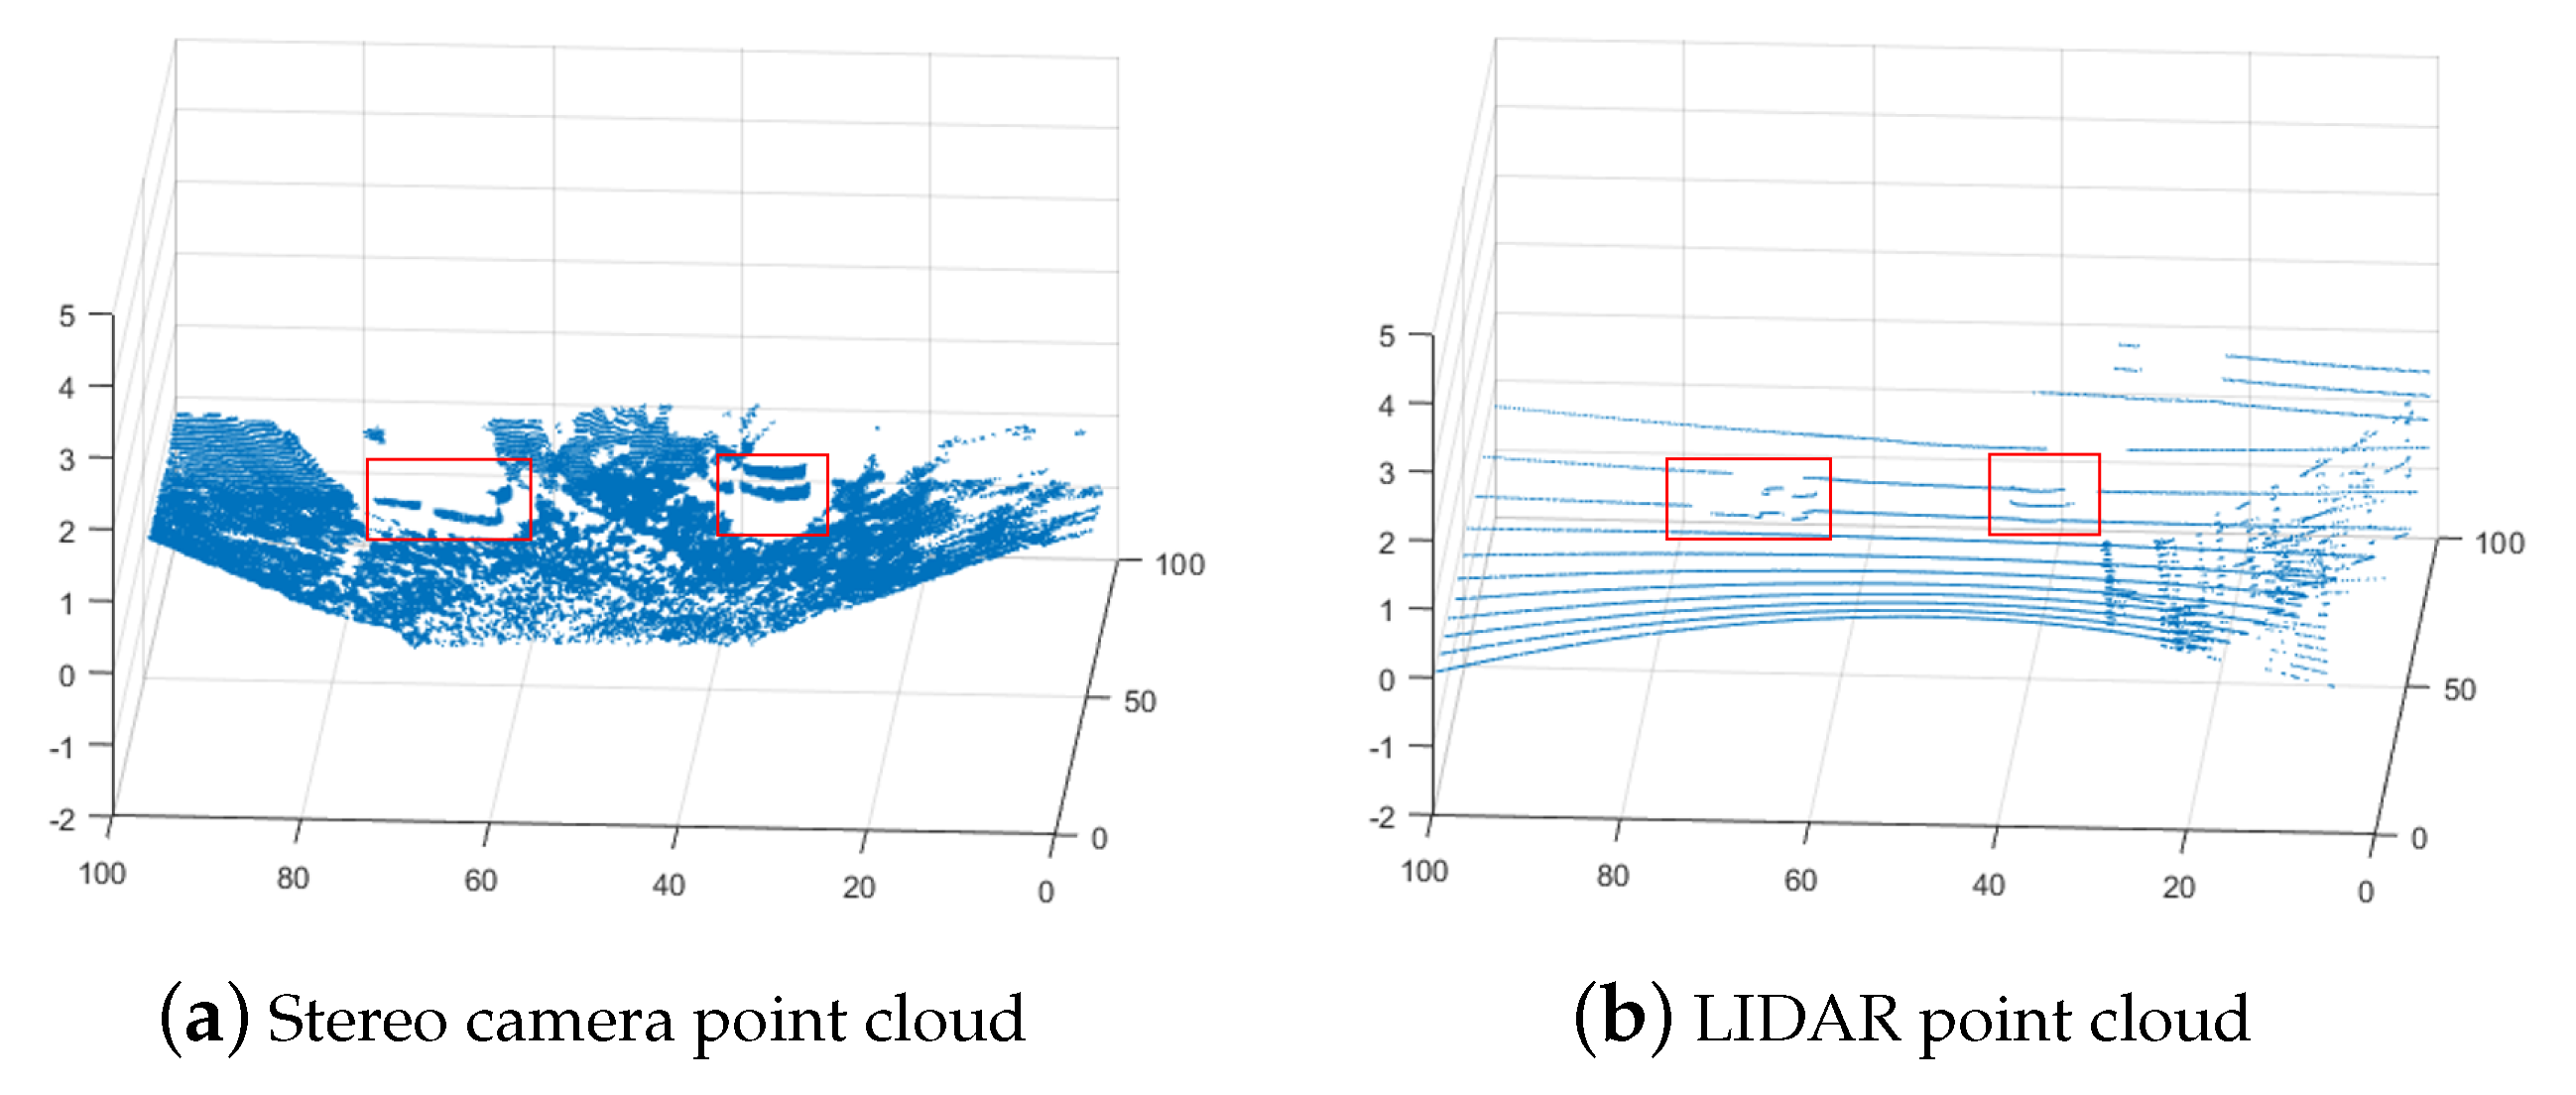
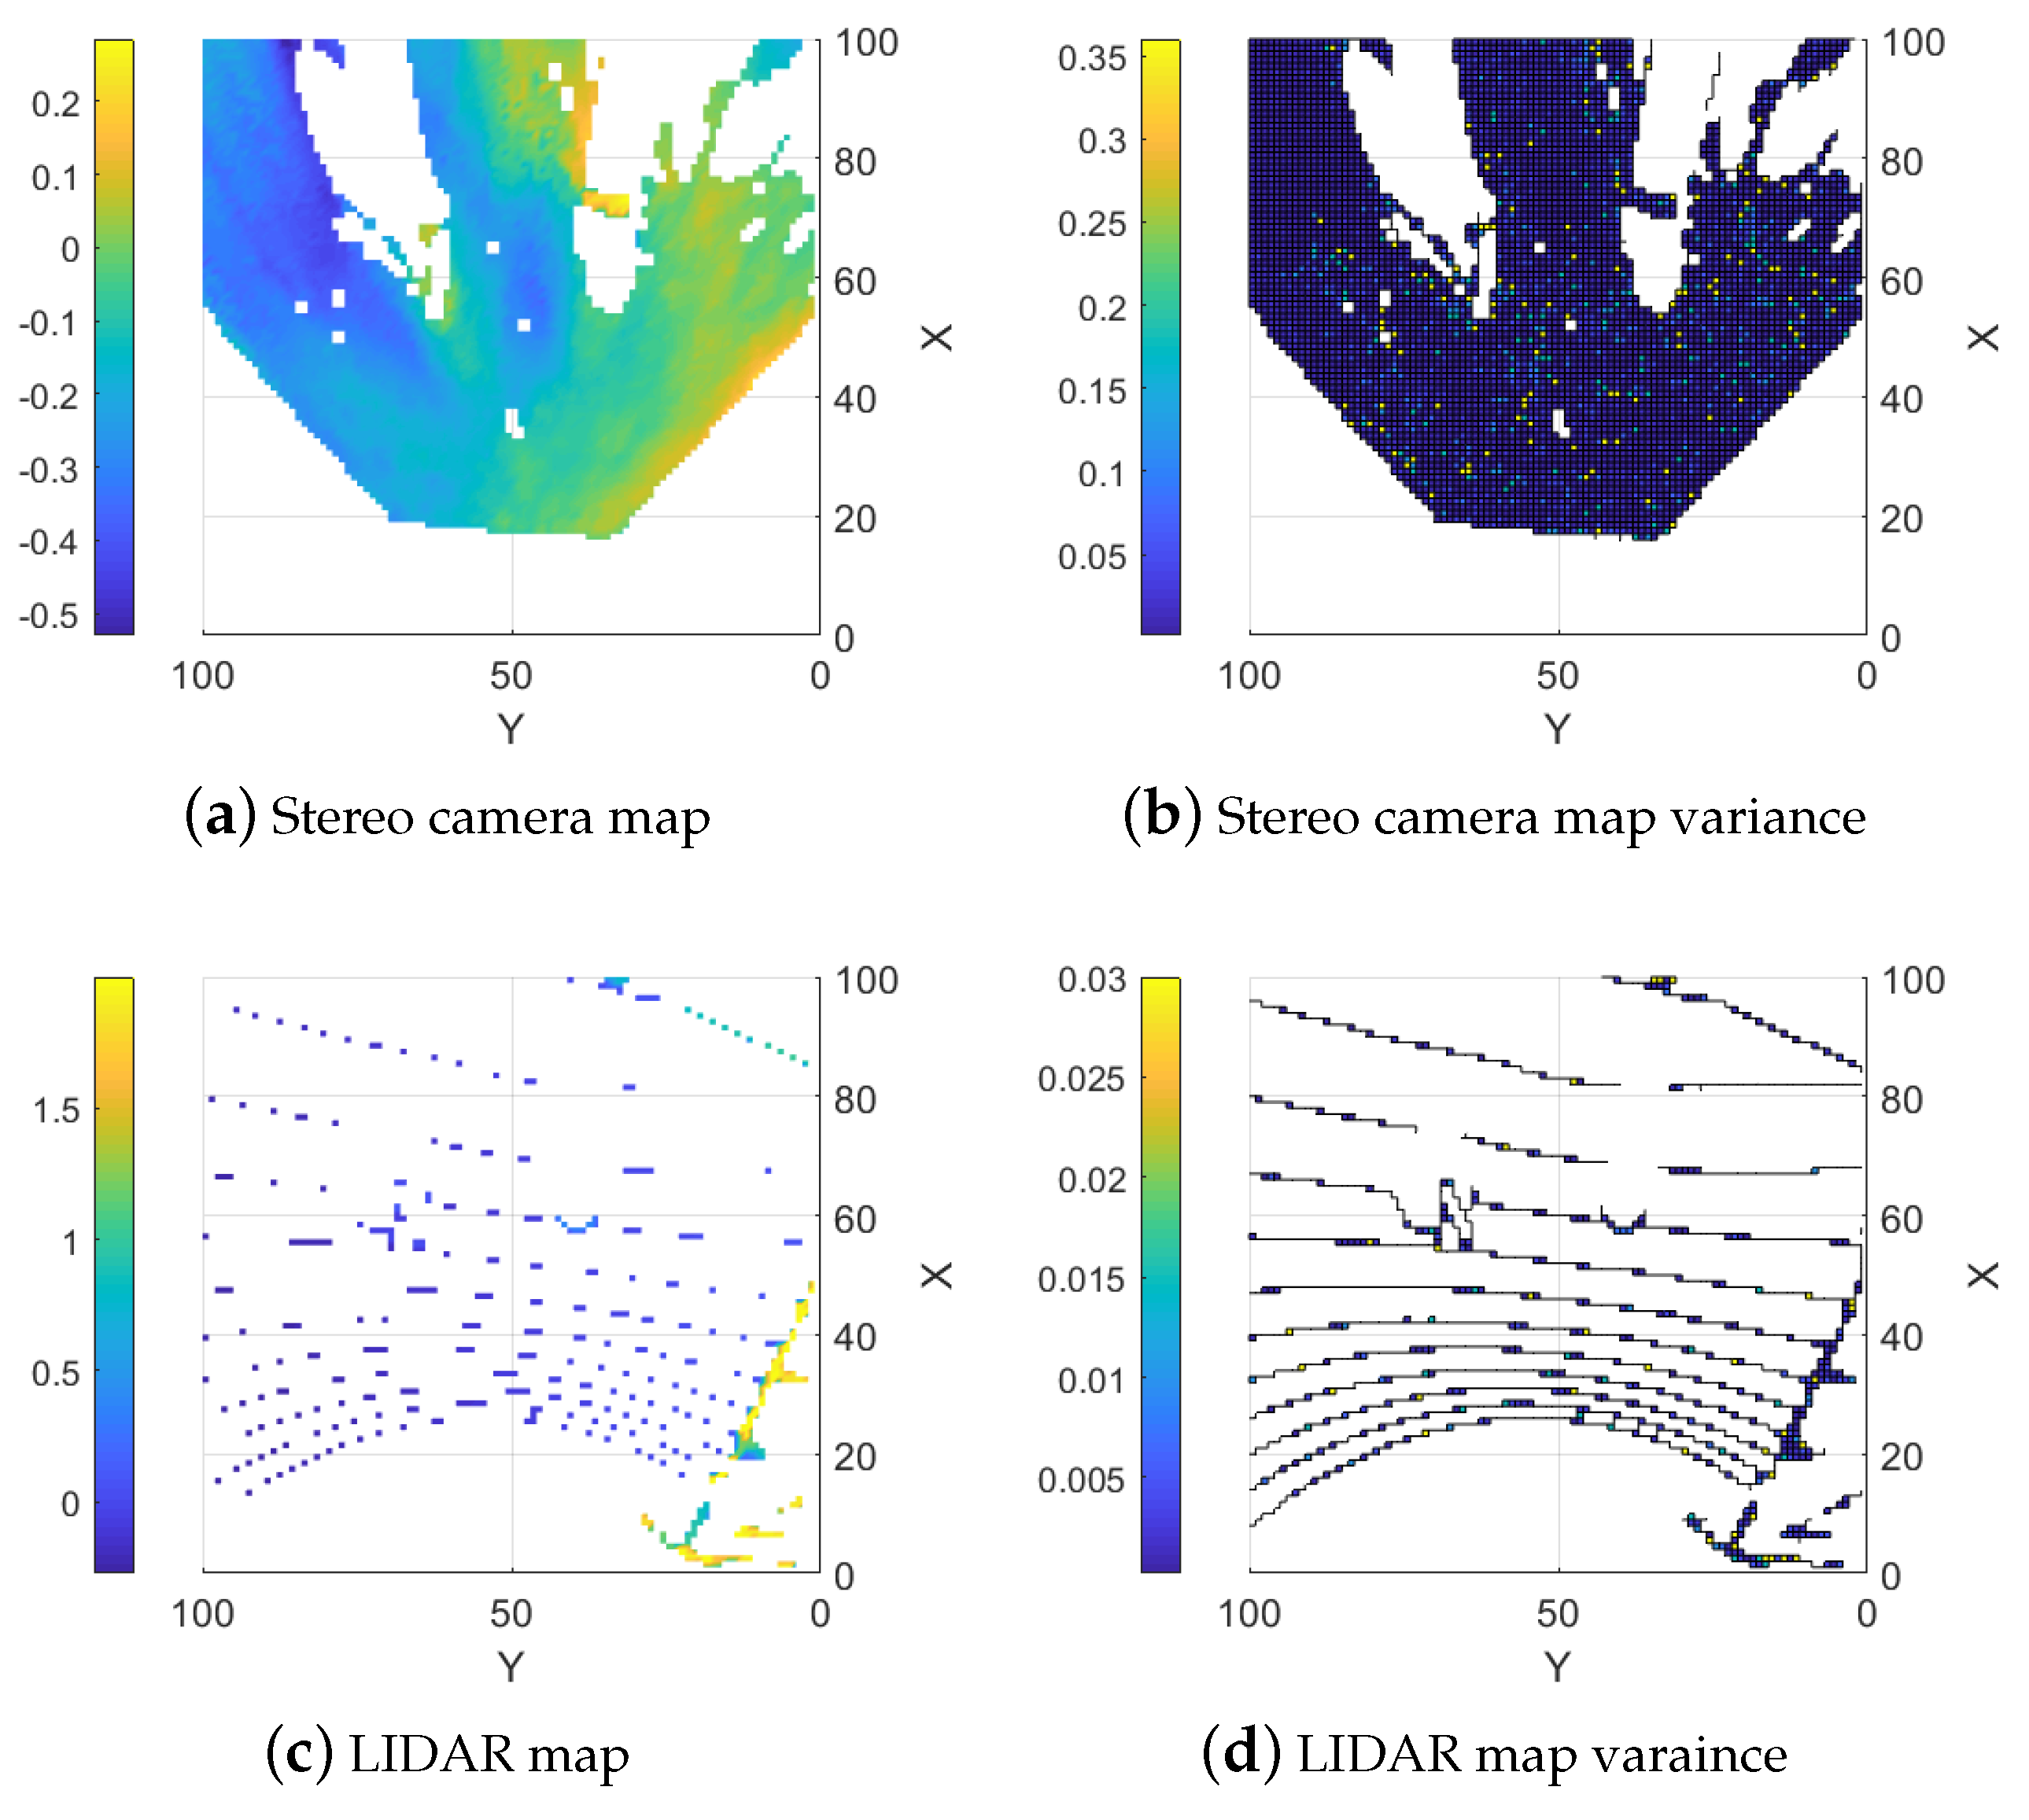
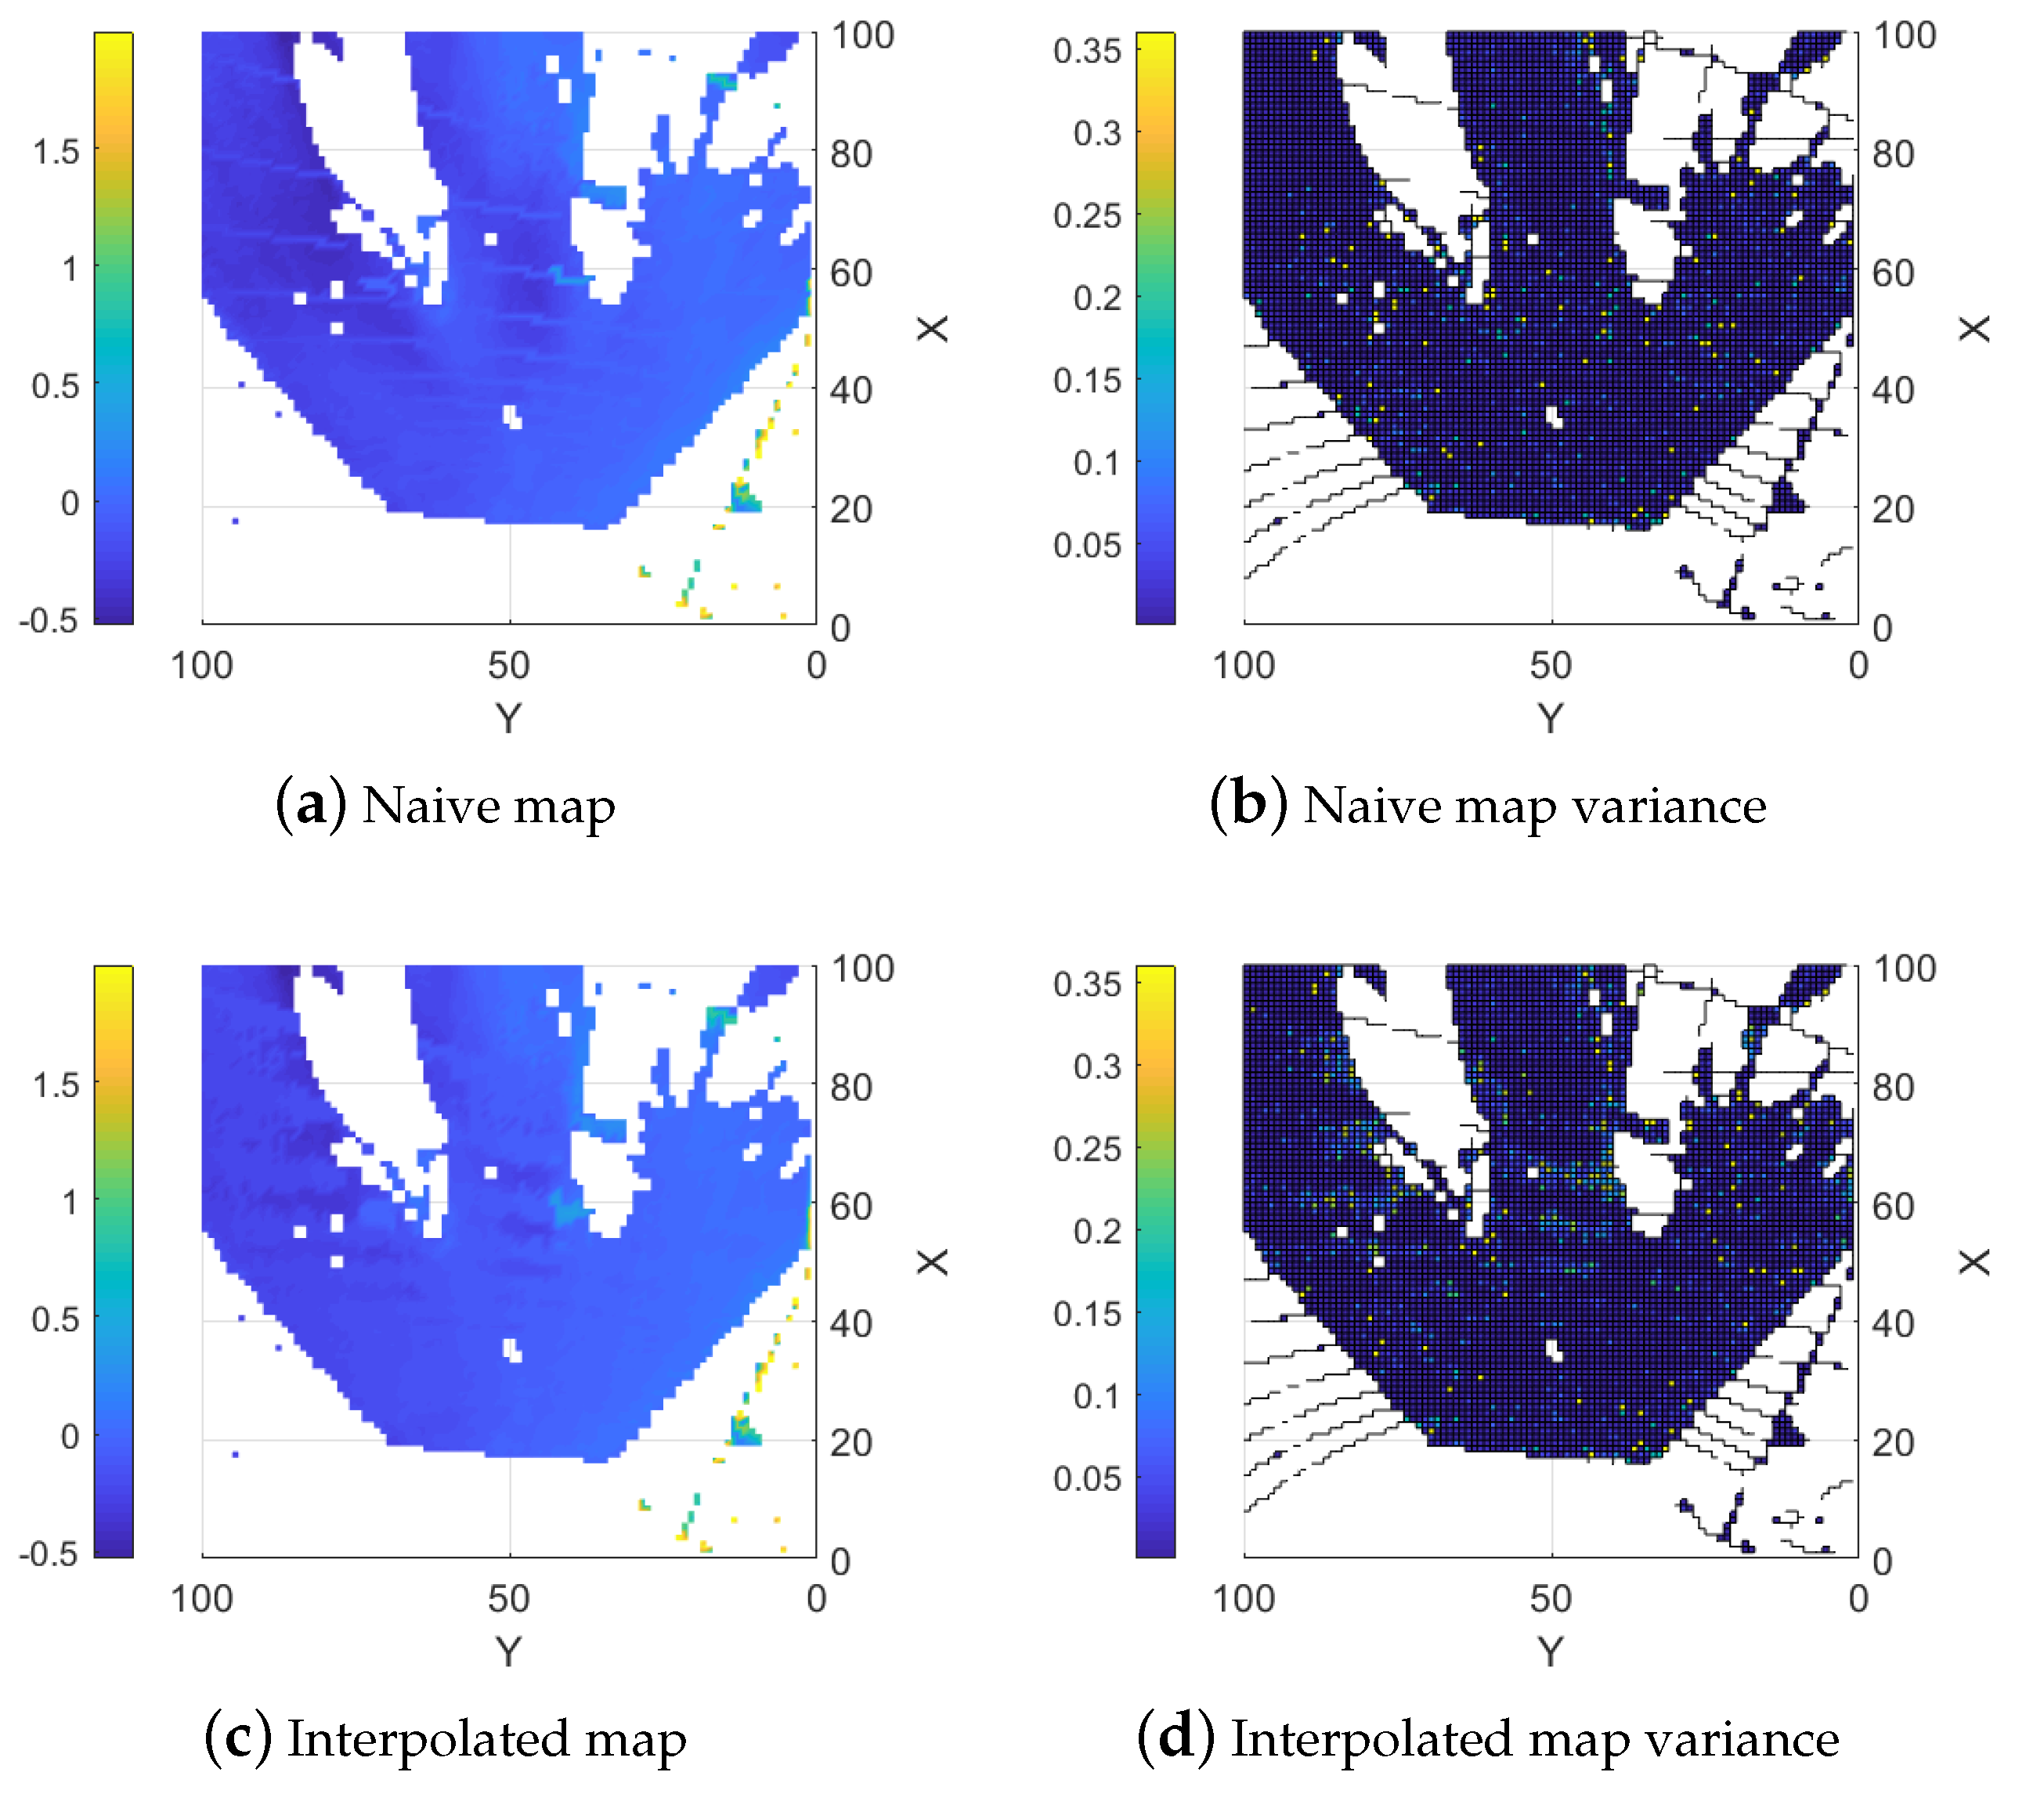
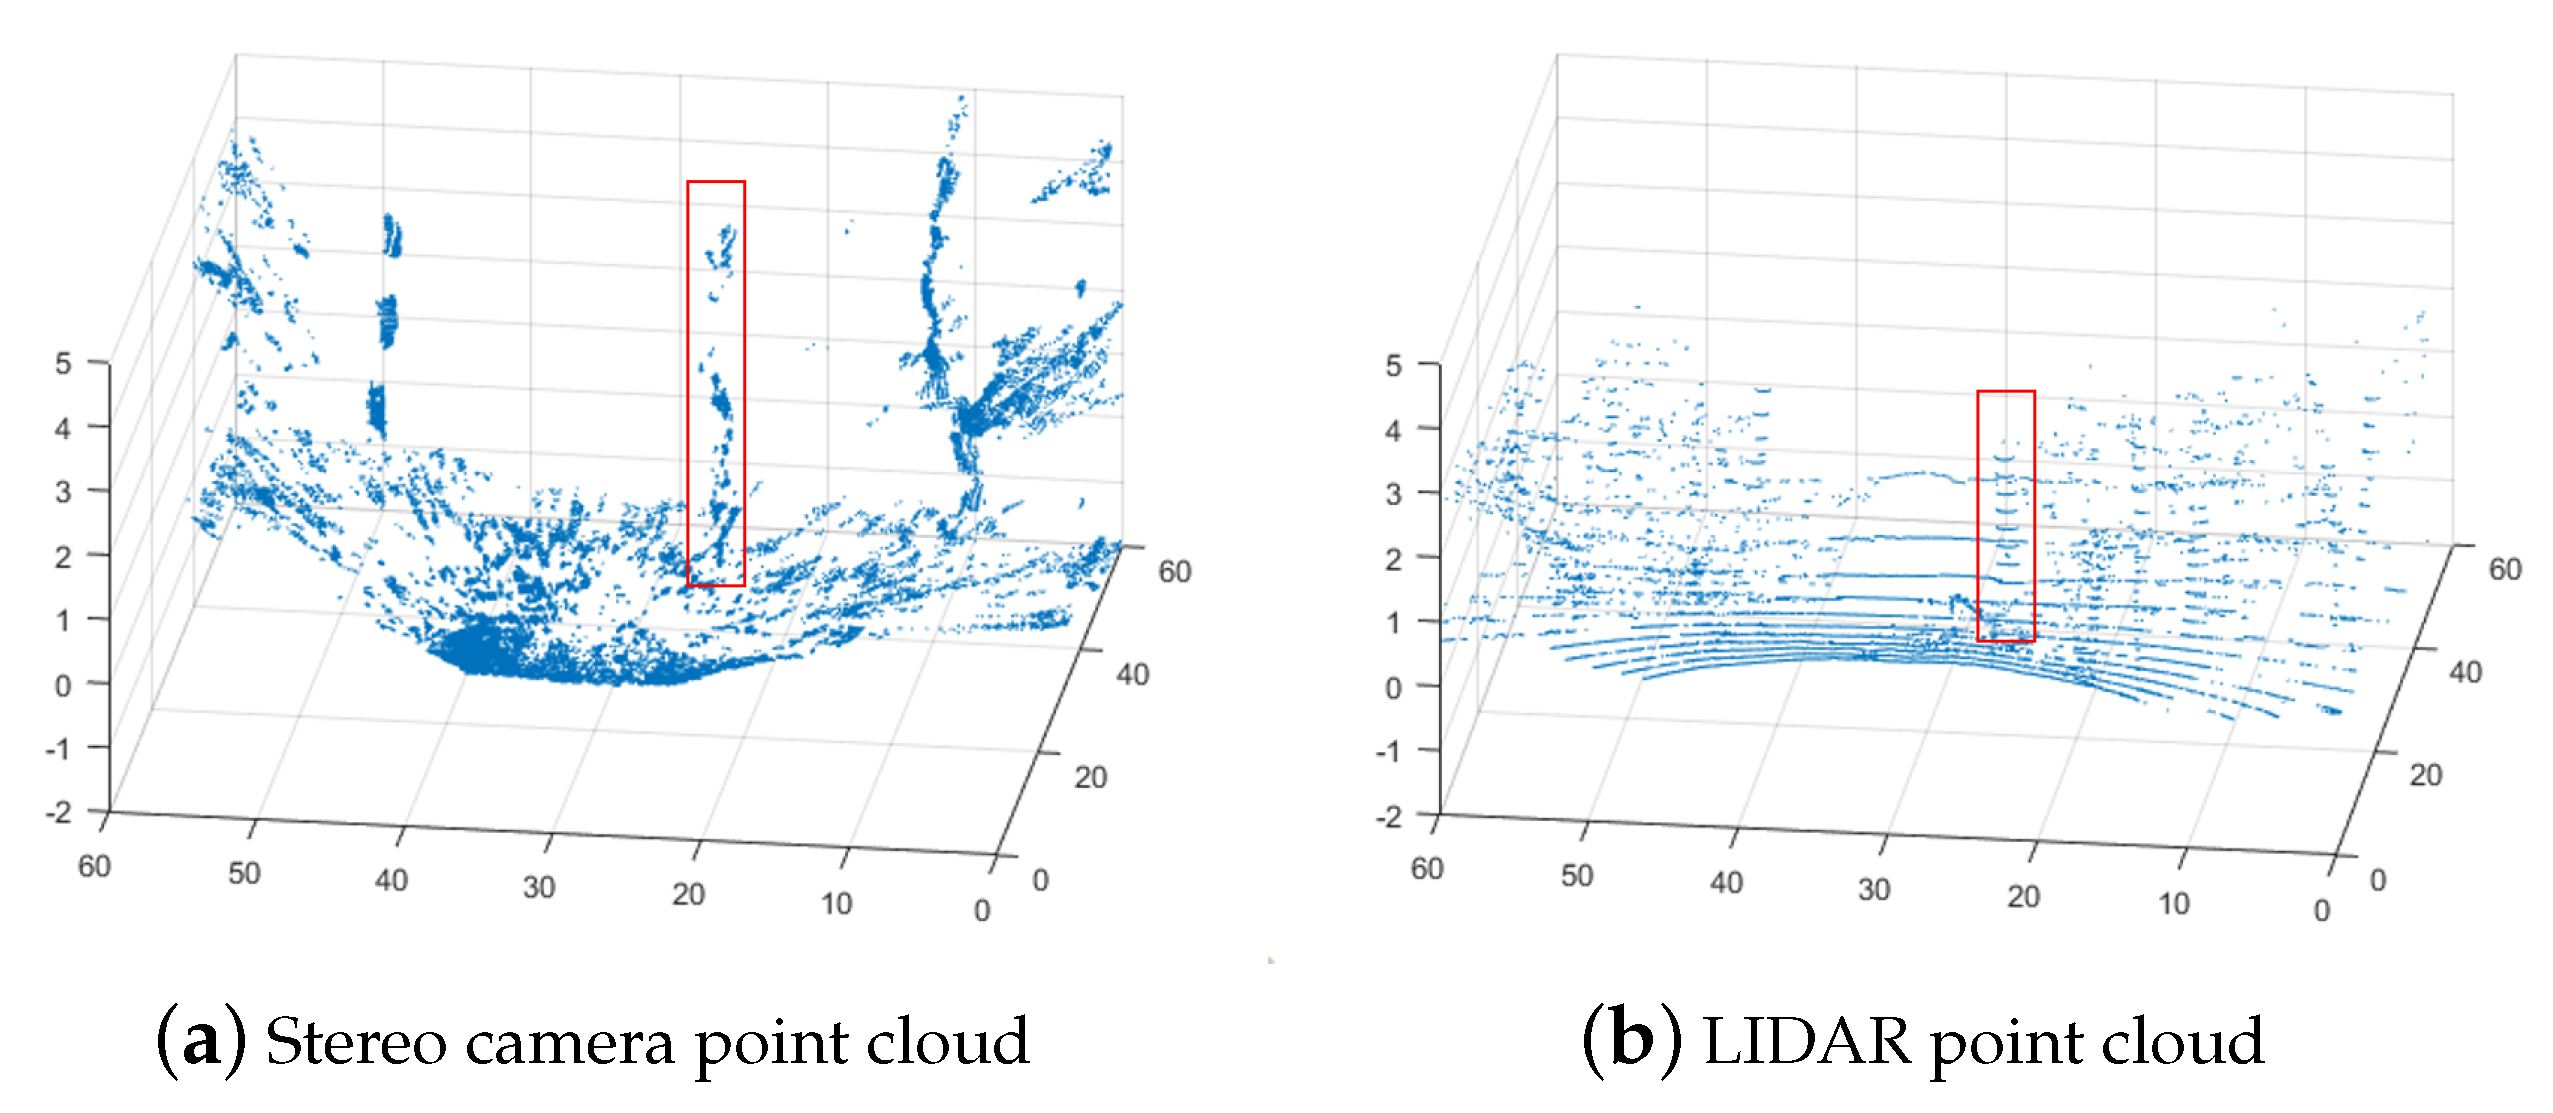
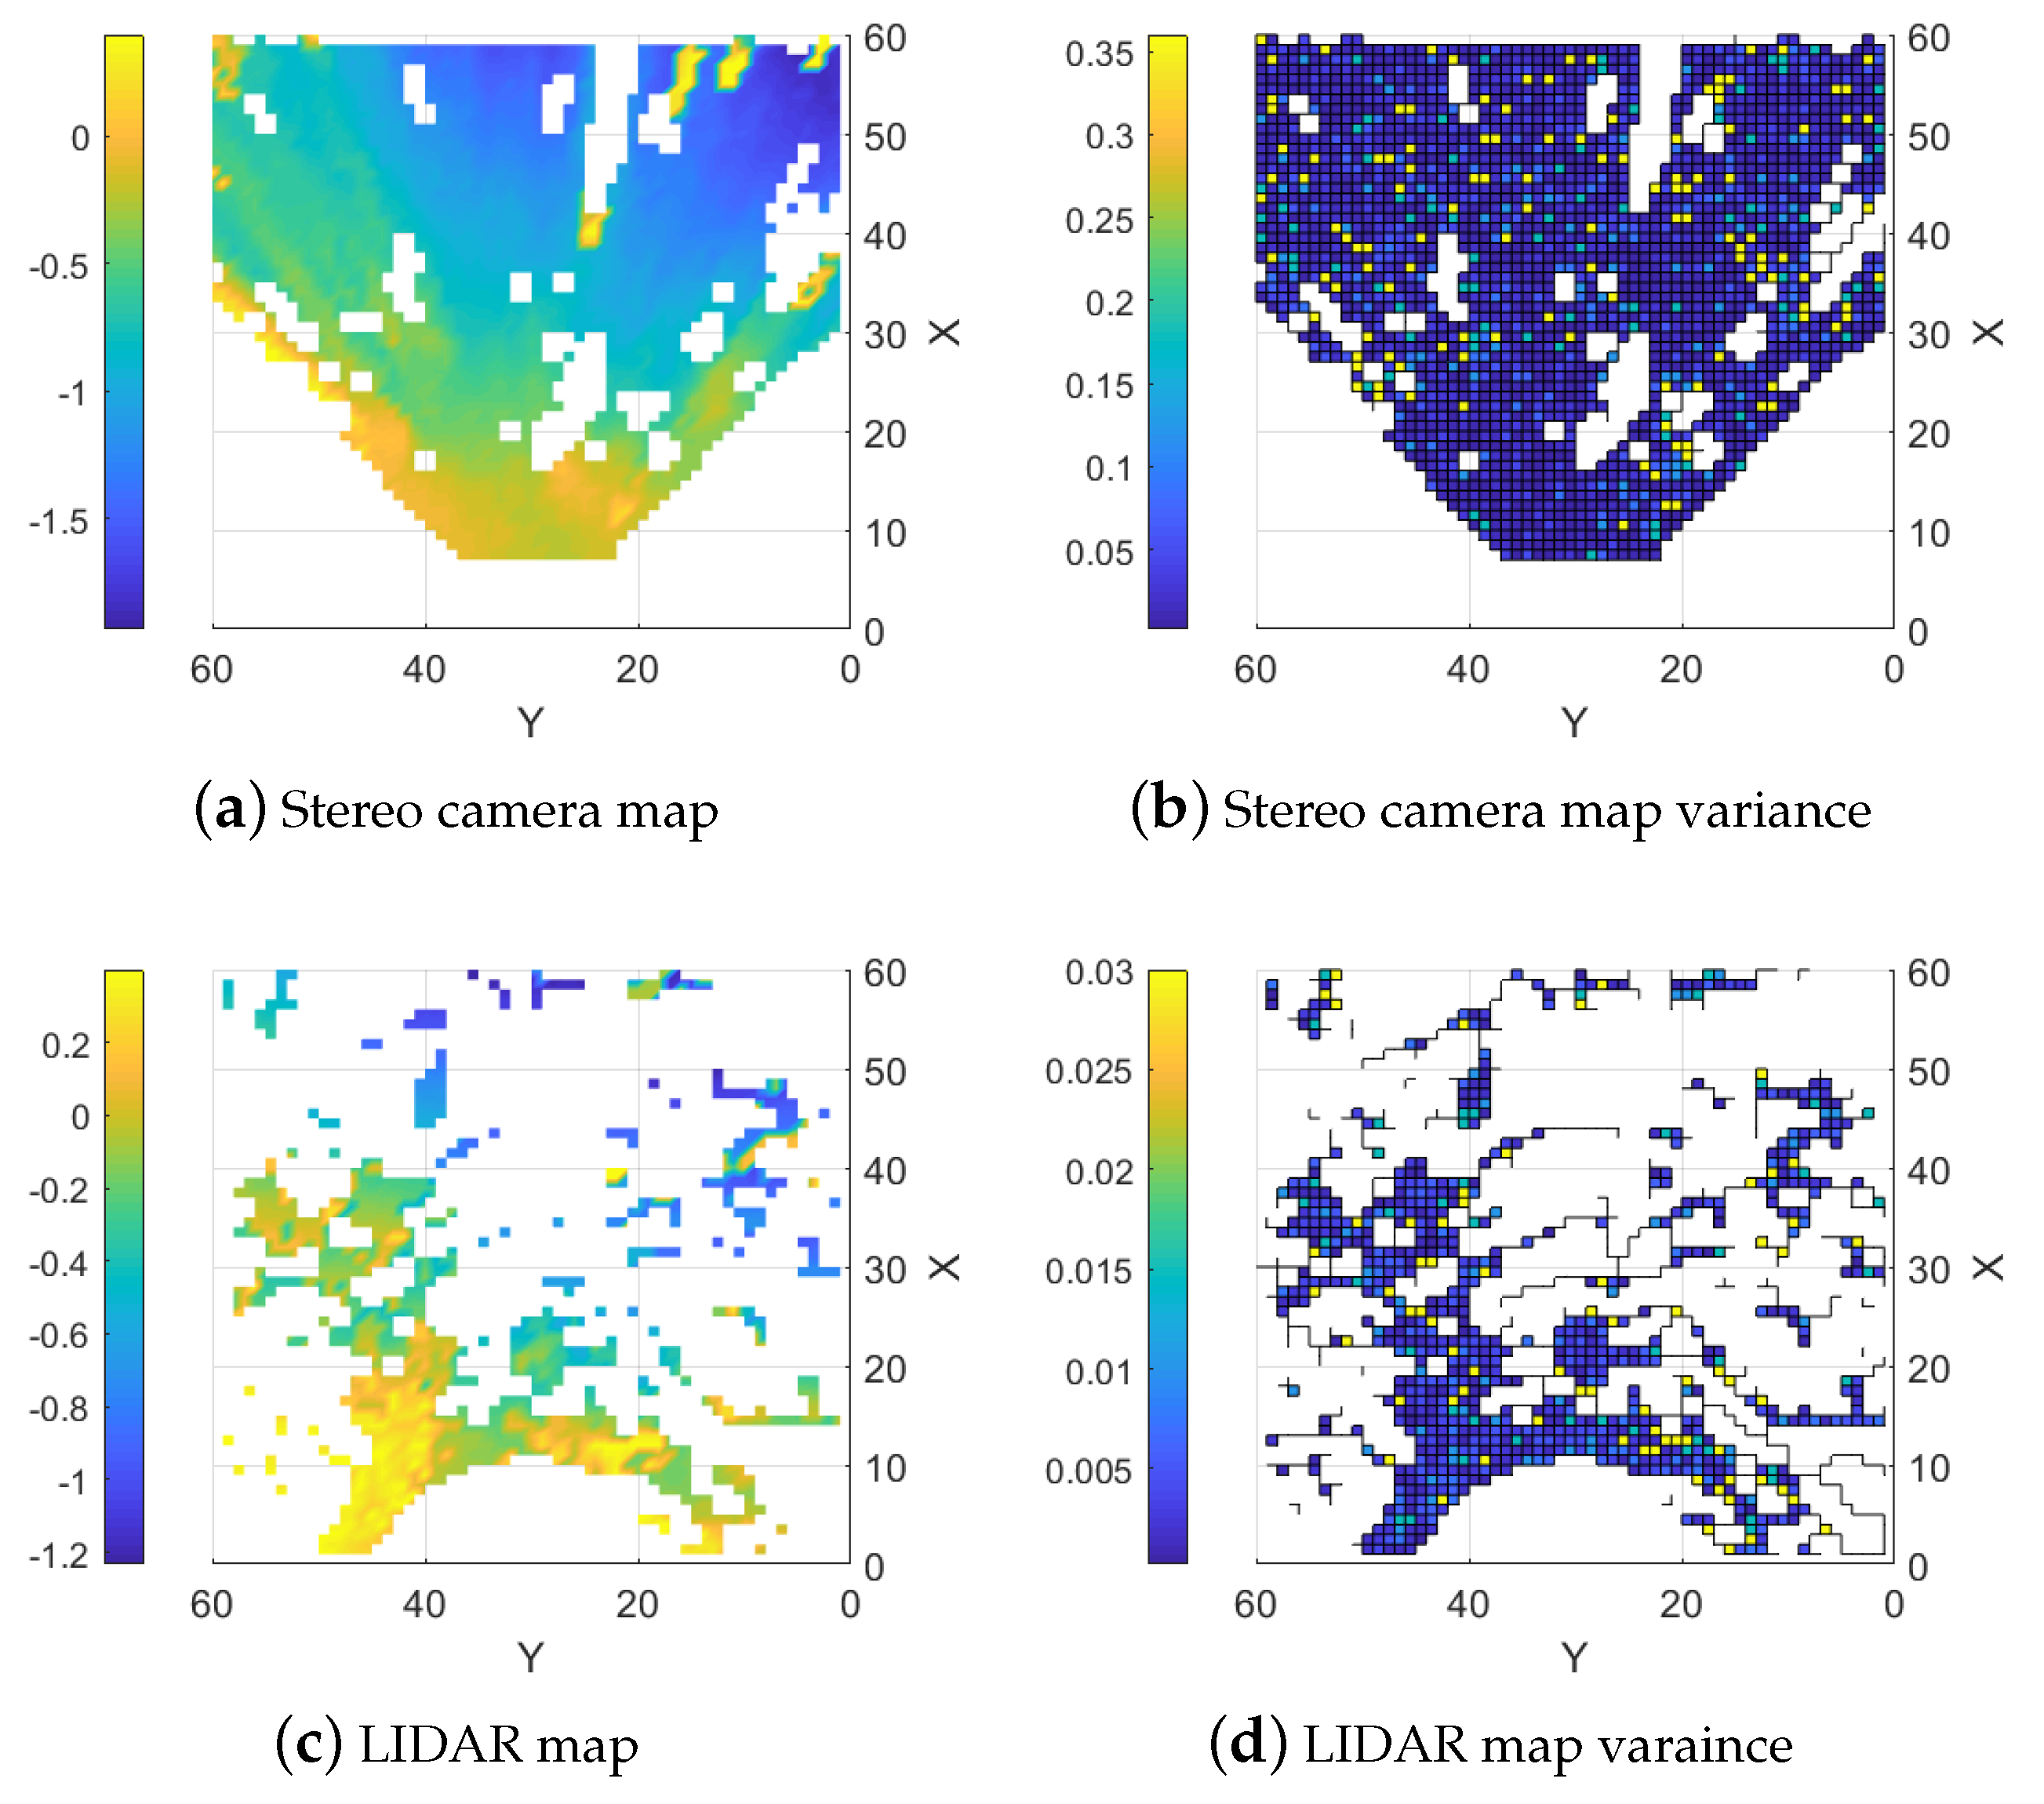
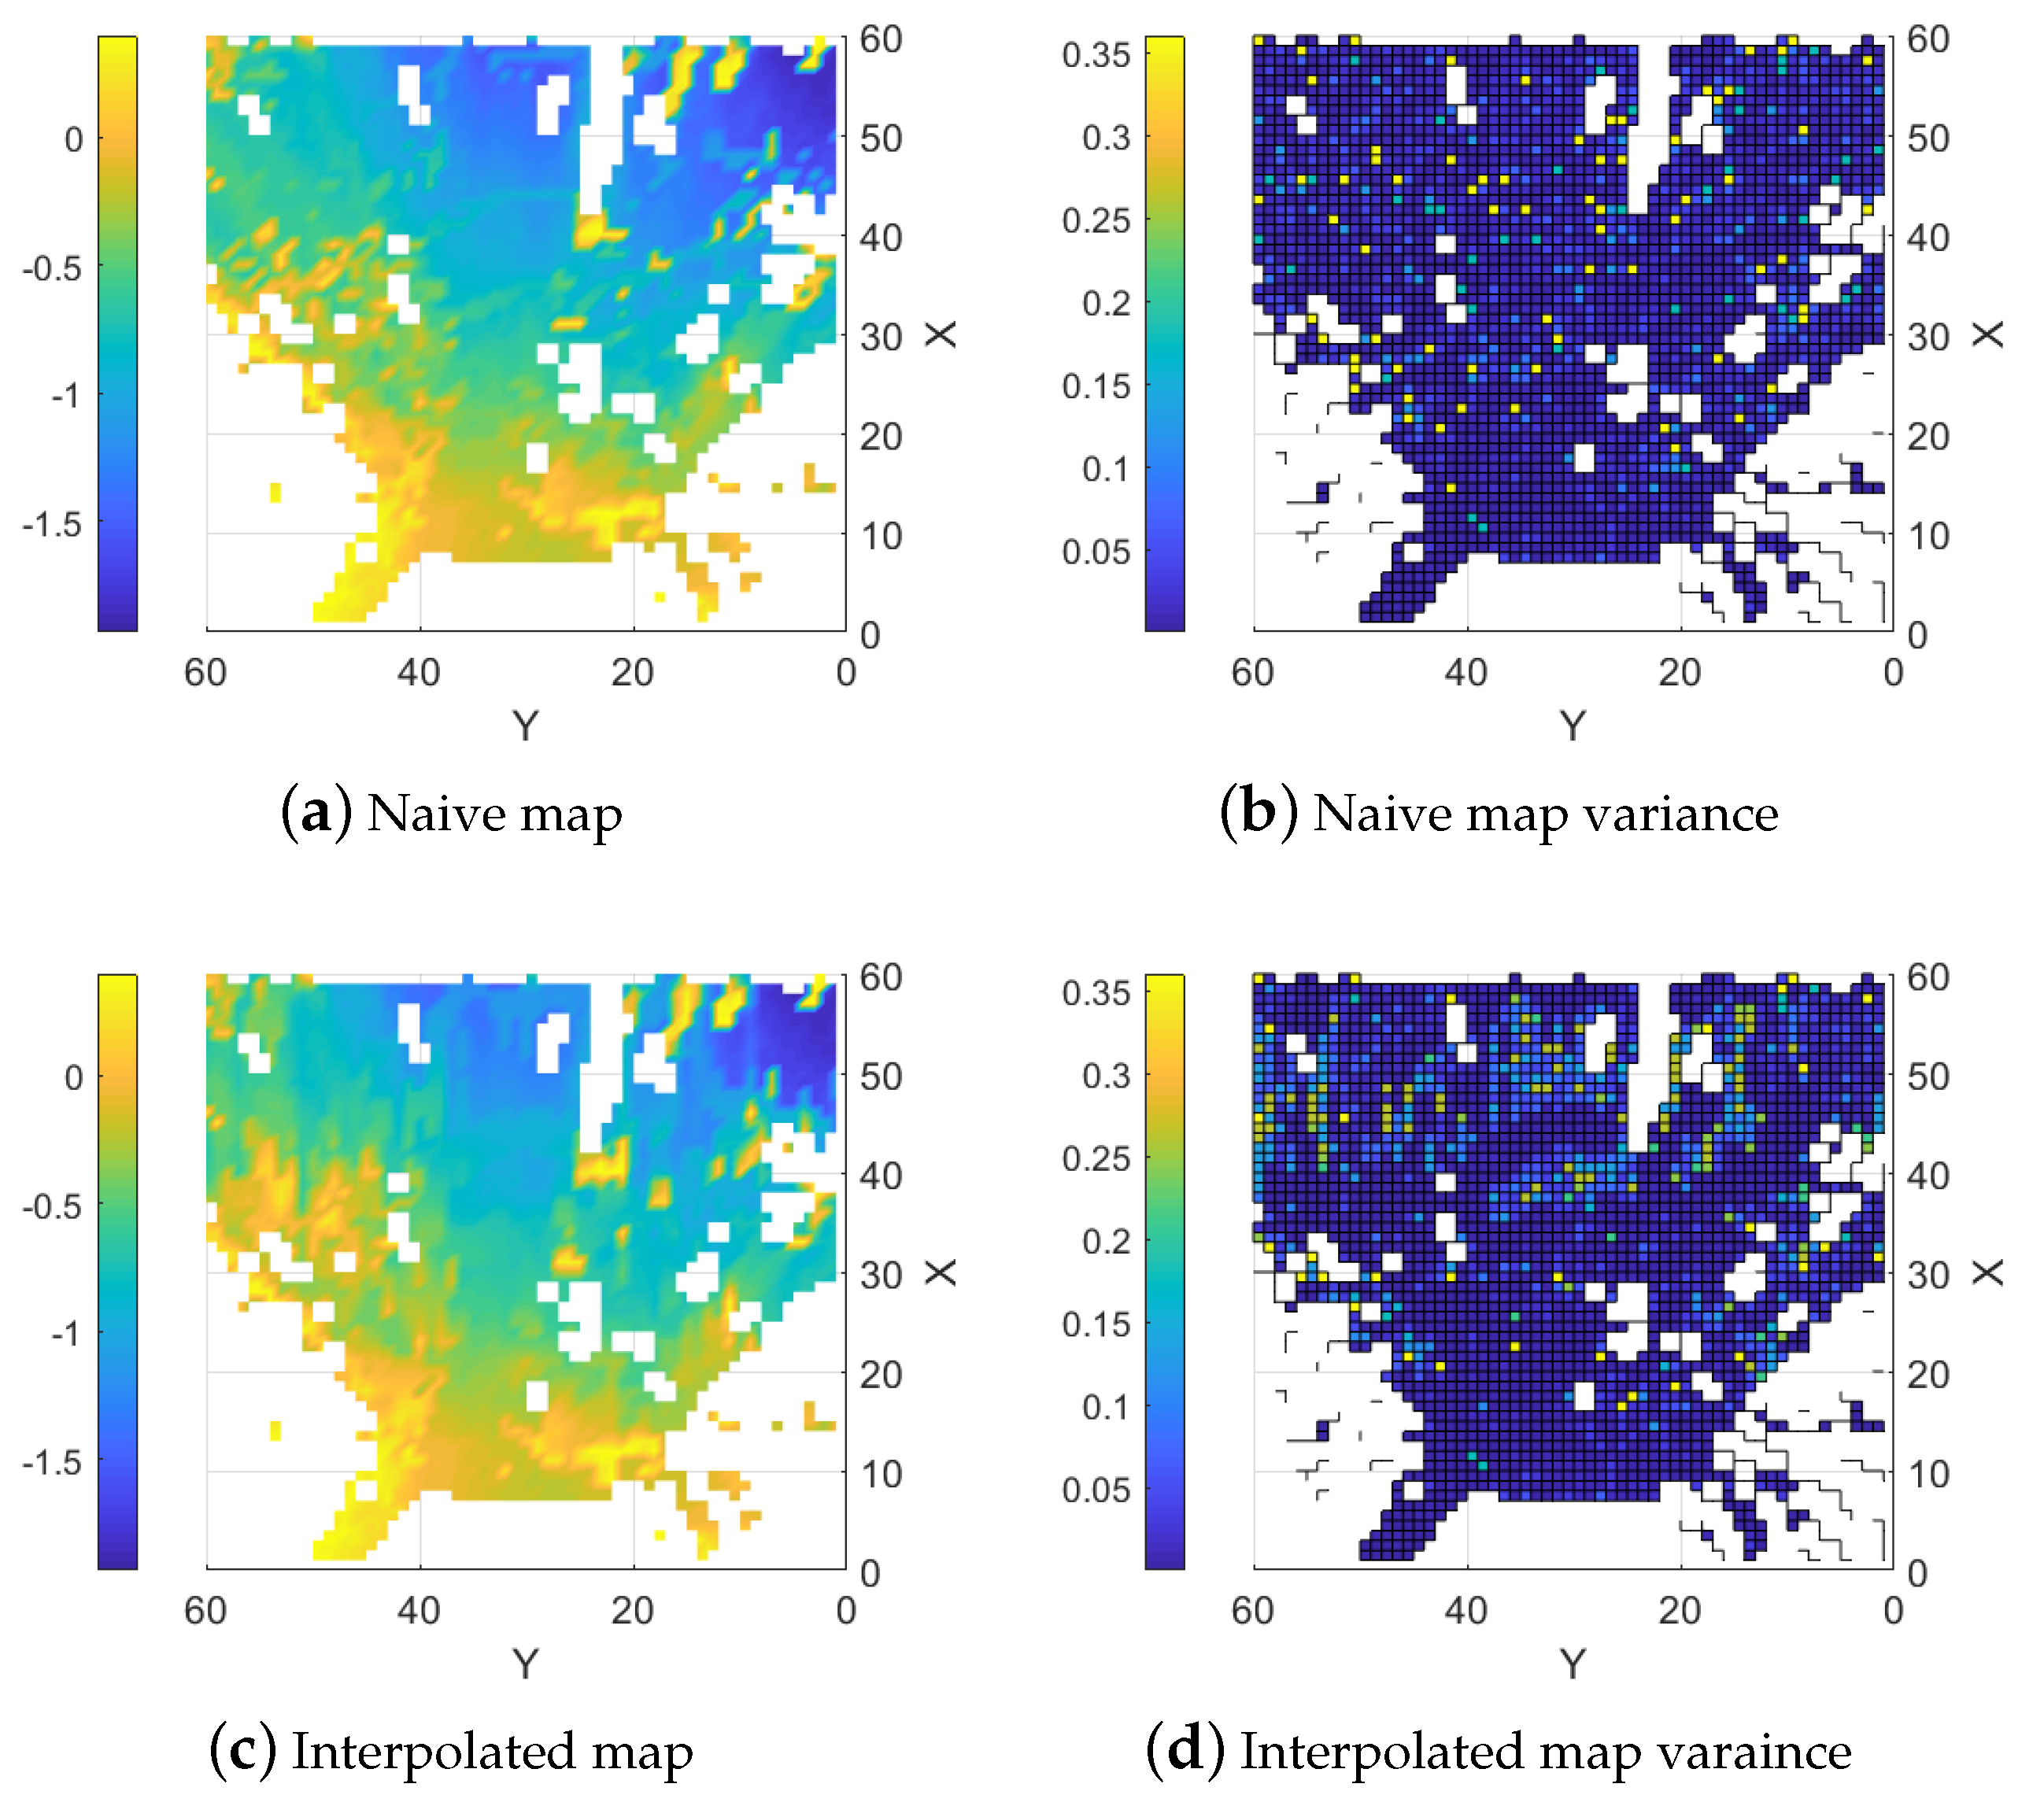
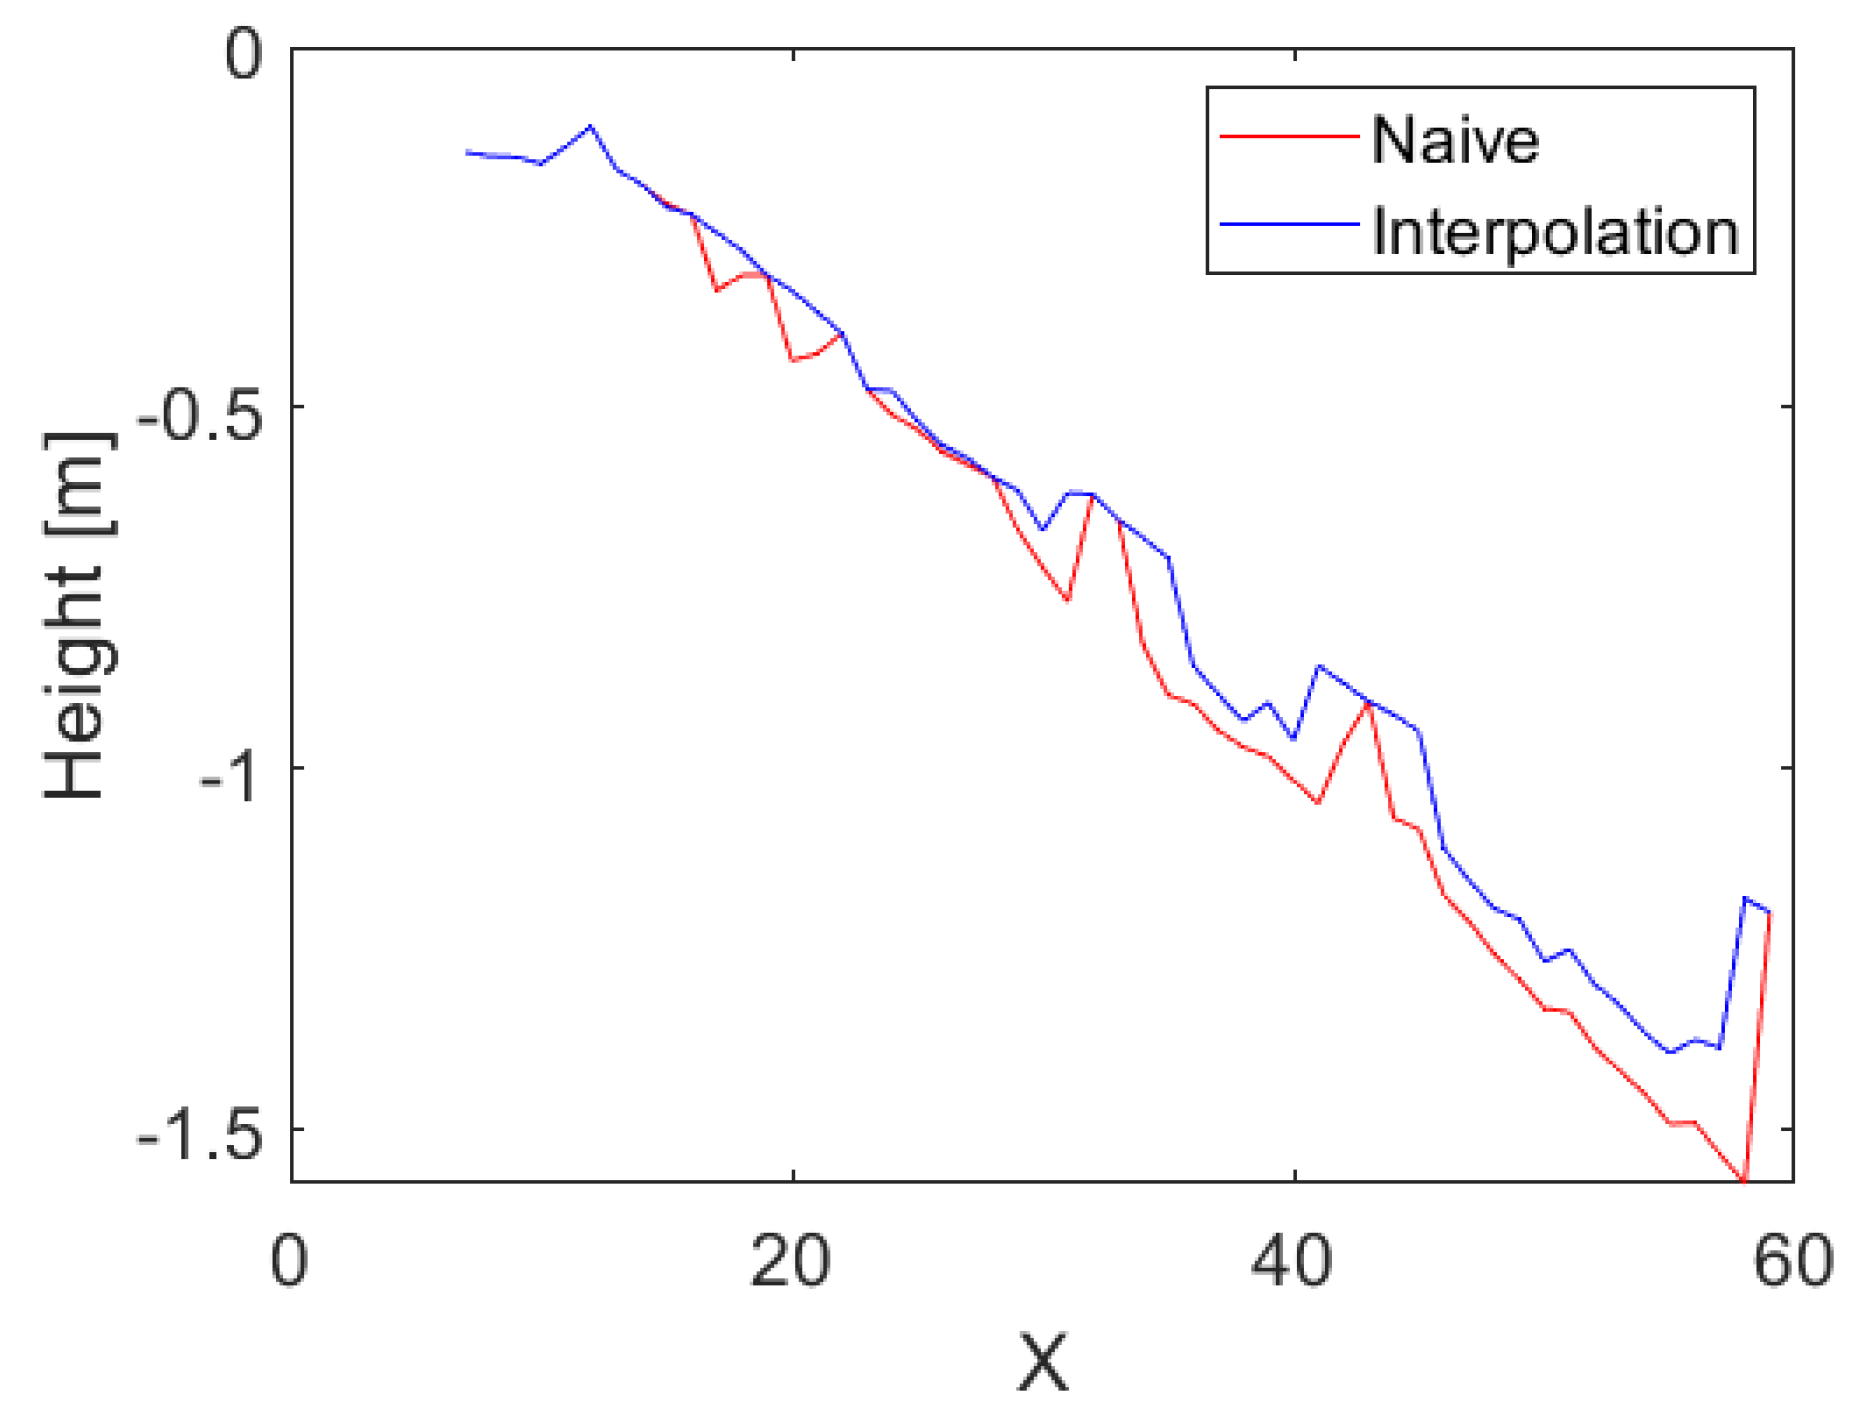
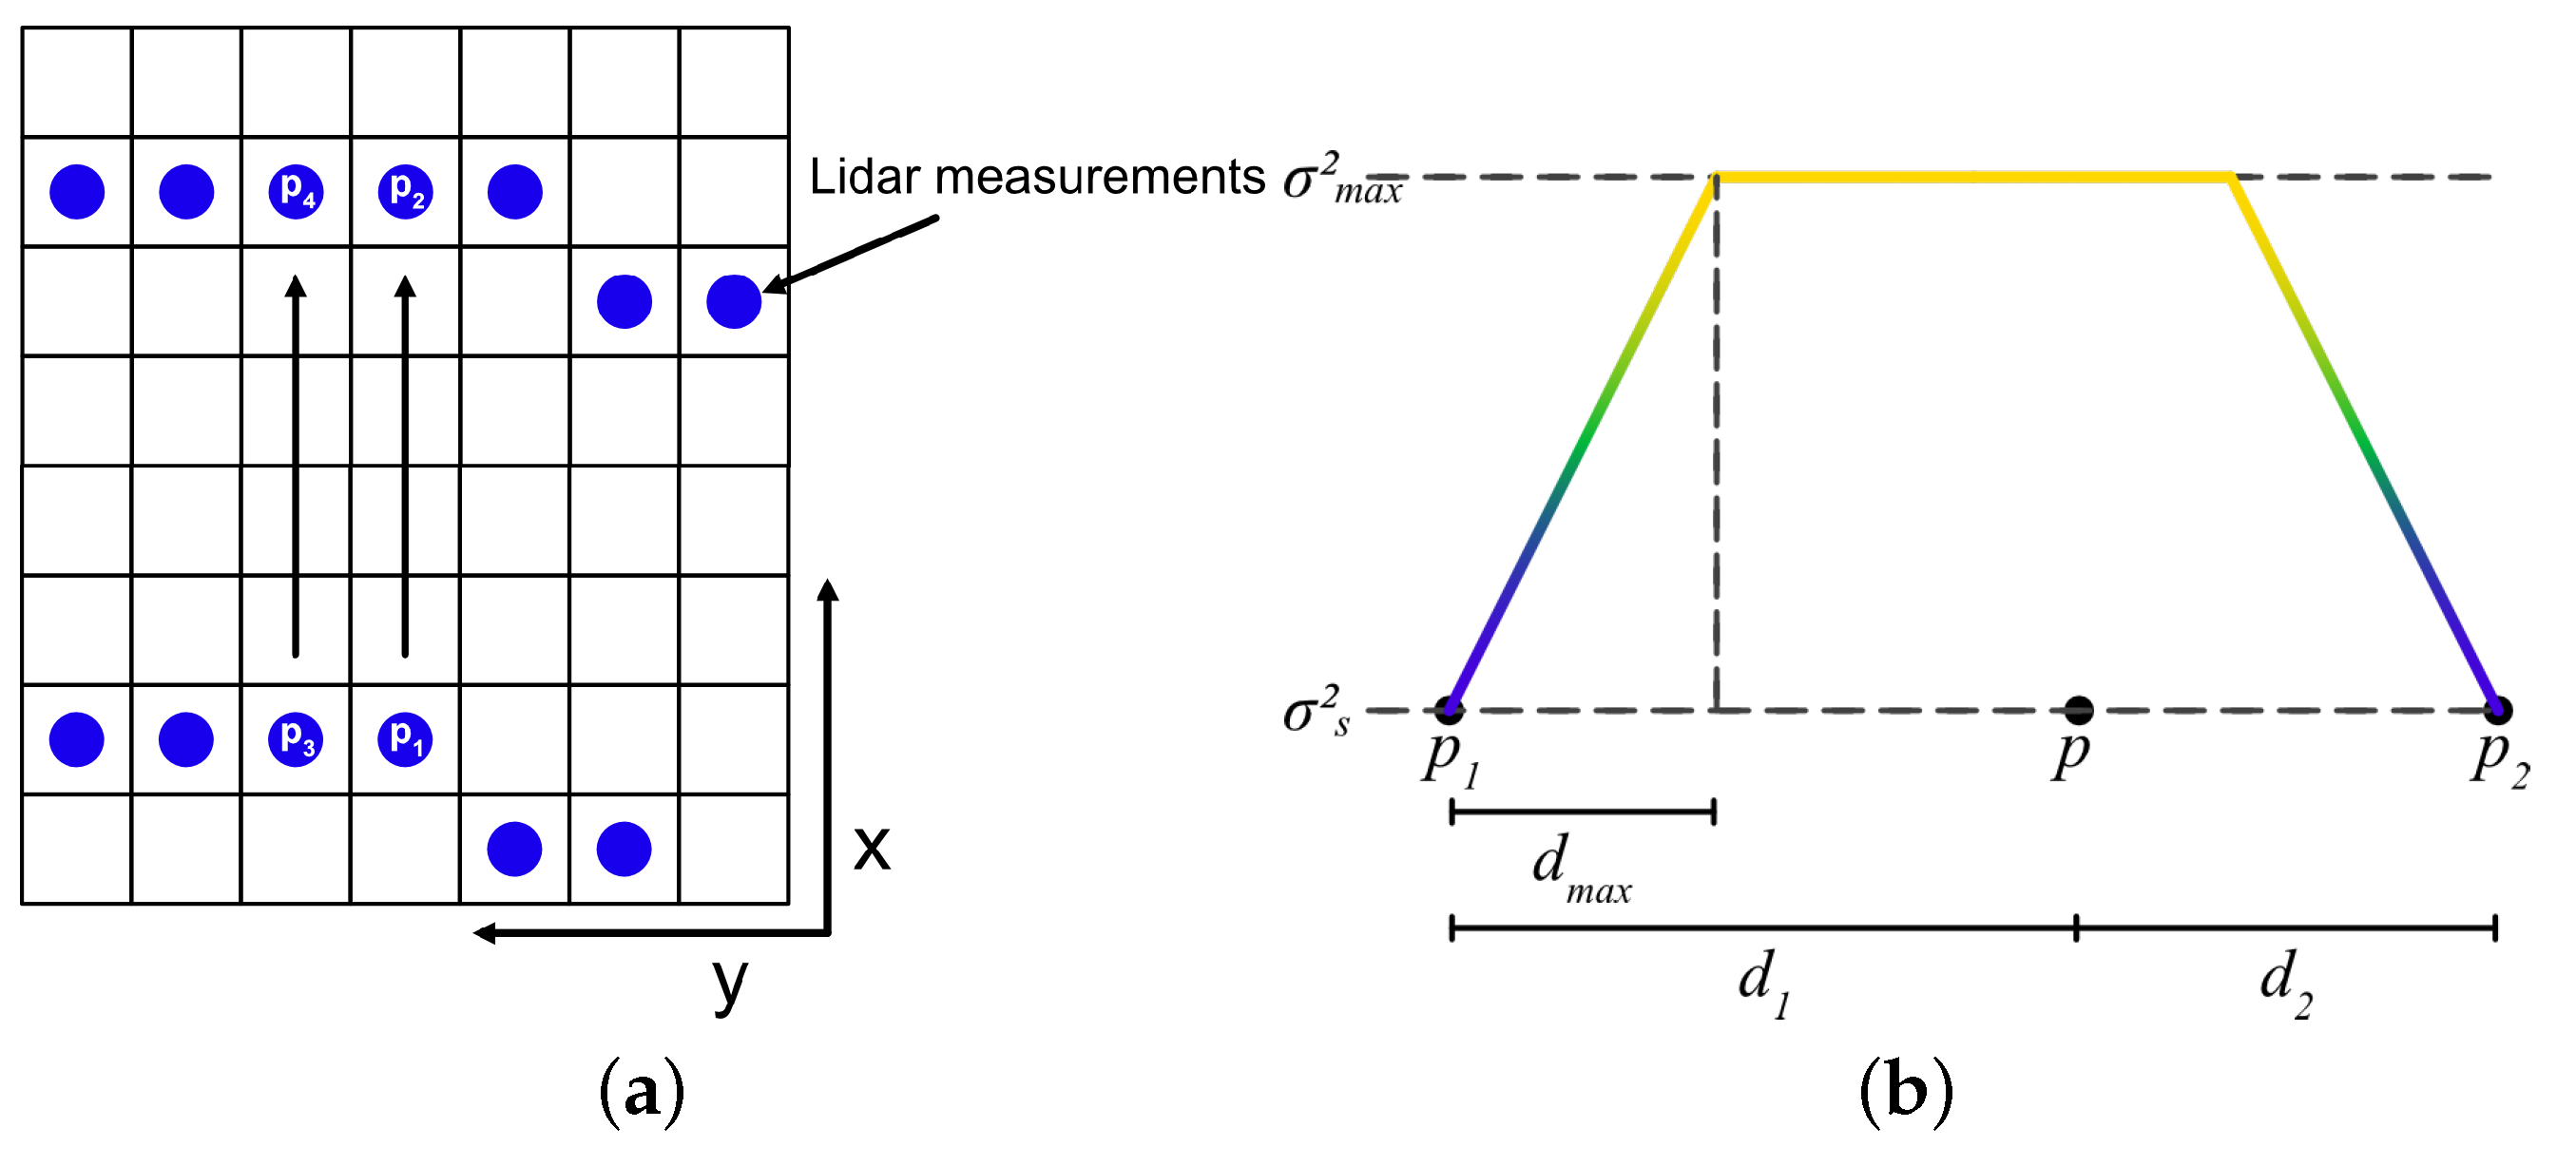
Topography estimation is essential for autonomous off-road navigation. Common methods rely on point cloud data from, e.g., Light Detection and Ranging sensors (LIDARs) and stereo cameras. Stereo cameras produce dense point clouds with larger coverage but lower accuracy. LIDARs, on the other hand, have higher accuracy and longer range but much less coverage. LIDARs are also more expensive. The research question examines whether incorporating LIDARs can significantly improve stereo camera accuracy. Current sensor fusion methods use LIDARs’ raw measurements directly; thus, the improvement in estimation accuracy is limited to only LIDAR-scanned locations The main contribution of our new method is to construct a reference ground plane through the interpolation of LIDAR data so that the interpolated maps have similar coverage as the stereo camera’s point cloud. The interpolated maps are fused with the stereo camera point cloud via Kalman filters to improve a larger section of the topography map. The method is tested in three environments: controlled indoor, semi-controlled outdoor, and unstructured terrain. Compared to the existing method without LIDAR interpolation, the proposed approach reduces average error by 40% in the controlled environment and 67% in the semi-controlled environment, while maintaining large coverage. The unstructured environment evaluation confirms its corrective impact.
Keywords: sensor-fusion; topography estimation; ground interpolation; Kalman filter; off-road navigation sensor-fusion; topography estimation; ground interpolation; Kalman filter; off-road navigation