Dynamic Indoor Localization Using Maximum Likelihood Particle Filtering

Abstract
1. Introduction
2. Problem Description
3. Available Solution Using Particle Filtering
4. Proposed Algorithm
| Algorithm 1 Proposed localization algorithm. |
At , initialize using (7). At each :
|
5. Experimental Validation
6. Conclusions
Author Contributions
Funding
Institutional Review Board Statement
Informed Consent Statement
Data Availability Statement
Conflicts of Interest
Appendix A. Non-Linear Robot Motion Models
Appendix A.1. Velocity Model
Appendix A.2. Odometry Model
Appendix A.3. Differential Drive Model
Appendix B. Linear Motion Model
Appendix C. Proofs
- 1.
- It follows straightforwardly from [34] (§ 5.4) thatSince the variance of is small, we can do the following approximation,where to simplify the notation we used .
- 2.
- We haveThen, from (A2),where ∗ denotes a non-zero term whose value is irrelevant. Then
- 3.
- Now, using (10) and (A1), we getBut, from (A3),NowHence
- 4.
- Putting (A4) and (A6) into (A5) we obtainand the result follows.
References
- Saab, S.S.; Nakad, Z.S. A standalone RFID indoor positioning system using passive tags. IEEE Trans. Ind. Electron. 2010, 58, 1961–1970. [Google Scholar] [CrossRef] [Scilit]
- Seco, F.; Jiménez, A.R. Smartphone-Based Cooperative Indoor Localization with RFID Technology. Sensors 2018, 18, 266. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Hallberg, J.; Nilsson, M.; Synnes, K. Positioning with bluetooth. In Proceedings of the 10th International Conference on Telecommunications 2003 (ICT 2003), Papeete, Tahiti, French Polynesia, 23 Feburary–1 March 2003; Volume 2, pp. 954–958. [Google Scholar]
- Yuan, Z.; Yang, J.; You, L.; Qi, L.; Naser, E.S. Smartphone-Based Indoor Localization with Bluetooth Low Energy Beacons. Sensors 2016, 16, 596. [Google Scholar]
- Gigl, T.; Janssen, G.J.; Dizdarevic, V.; Witrisal, K.; Irahhauten, Z. Analysis of a UWB indoor positioning system based on received signal strength. In Proceedings of the 2007 4th Workshop on Positioning, Navigation and Communication, Hannover, Germany, 22 March 2007; pp. 97–101. [Google Scholar]
- Mazhar, F.; Khan, M.G.; Sällberg, B. Precise indoor positioning using UWB: A review of methods, algorithms and implementations. Wirel. Pers. Commun. 2017, 97, 4467–4491. [Google Scholar] [CrossRef] [Scilit]
- Yang, C.; Shao, H.R. WiFi-based indoor positioning. IEEE Commun. Mag. 2015, 53, 150–157. [Google Scholar] [CrossRef] [Scilit]
- Jian, C.; Gang, O.; Ao, P.; Zheng, L.; Shi, J. An INS/WiFi Indoor Localization System Based on the Weighted Least Squares. Sensors 2018, 18, 1458. [Google Scholar]
- Yang, Z.; Zhou, Z.; Liu, Y. From RSSI to CSI: Indoor localization via channel response. ACM Comput. Surv. (CSUR) 2013, 46, 1–32. [Google Scholar] [CrossRef] [Scilit]
- Zafari, F.; Gkelias, A.; Leung, K.K. A survey of indoor localization systems and technologies. IEEE Commun. Surv. Tutor. 2019, 21, 2568–2599. [Google Scholar] [CrossRef] [Scilit]
- Schatzberg, U.; Banin, L.; Amizur, Y. Enhanced WiFi ToF indoor positioning system with MEMS-based INS and pedometric information. In Proceedings of the 2014 IEEE/ION Position, Location and Navigation Symposium-PLANS 2014, Monterey, CA, USA, 5–8 May 2014; pp. 185–192. [Google Scholar]
- Kotaru, M.; Joshi, K.; Bharadia, D.; Katti, S. Spotfi: Decimeter level localization using wifi. In Proceedings of the 2015 ACM Conference on Special Interest Group on Data Communication, London, UK, 17–21 August 2015; pp. 269–282. [Google Scholar]
- Xia, S.; Liu, Y.; Yuan, G.; Zhu, M.; Wang, Z. Indoor fingerprint positioning based on Wi-Fi: An overview. ISPRS Int. J. Geo-Inf. 2017, 6, 135. [Google Scholar] [CrossRef] [Scilit]
- Wen, Y.; Tian, X.; Wang, X.; Lu, S. Fundamental limits of RSS fingerprinting based indoor localization. In Proceedings of the 2015 IEEE Conference on Computer Communications (INFOCOM), Kowloon, Hong Kong, 26 April–1 May 2015; pp. 2479–2487. [Google Scholar]
- Dardari, D.; Closas, P.; Djurić, P.M. Indoor tracking: Theory, methods, and technologies. IEEE Trans. Veh. Technol. 2015, 64, 1263–1278. [Google Scholar] [CrossRef] [Scilit]
- Belmonte-Hernández, A.; Hernández-Peñaloza, G.; Alvarez, F.; Conti, G. Adaptive fingerprinting in multi-sensor fusion for accurate indoor tracking. IEEE Sens. J. 2017, 17, 4983–4998. [Google Scholar] [CrossRef] [Scilit]
- Du, Y.; Yang, D.; Yang, H.; Xiu, C. Flexible indoor localization and tracking system based on mobile phone. J. Netw. Comput. Appl. 2016, 69, 107–116. [Google Scholar]
- Xu, W.; Liu, L.; Zlatanova, S.; Penard, W.; Xiong, Q. A pedestrian tracking algorithm using grid-based indoor model. Autom. Constr. 2018, 92, 173–187. [Google Scholar] [CrossRef] [Scilit]
- Deng, Z.A.; Hu, Y.; Yu, J.; Na, Z. Extended Kalman filter for real time indoor localization by fusing WiFi and smartphone inertial sensors. Micromachines 2015, 6, 523–543. [Google Scholar] [CrossRef] [Scilit]
- Belmonte-Hernández, A.; Hernández-Peñaloza, G.; Gutiérrez, D.M.; Álvarez, F. SWiBluX: Multi-Sensor Deep Learning Fingerprint for precise real-time indoor tracking. IEEE Sens. J. 2019, 19, 3473–3486. [Google Scholar] [CrossRef] [Scilit]
- Zhao, Z.; Braun, T.; Li, Z.; Neto, A. A real-time robust indoor tracking system in smartphones. Comput. Commun. 2018, 117, 104–115. [Google Scholar]
- Jia, R.; Jin, M.; Zou, H.; Yesilata, Y.; Xie, L.; Spanos, C. Mapsentinel: Can the knowledge of space use improve indoor tracking further? Sensors 2016, 16, 472. [Google Scholar] [CrossRef] [Scilit]
- Wu, C.; Zhang, F.; Wang, B.; Liu, K.R. EasiTrack: Decimeter-Level Indoor Tracking With Graph-Based Particle Filtering. IEEE Internet Things J. 2019, 7, 2397–2411. [Google Scholar] [CrossRef] [Scilit]
- Marelli, D.; Fu, M.; Ninness, B. Asymptotic Optimality of the Maximum-Likelihood Kalman Filter for Bayesian Tracking With Multiple Nonlinear Sensors. IEEE Trans. Signal Process. 2015, 63, 4502–4515. [Google Scholar] [CrossRef] [Scilit]
- Wang, W.; Marelli, D.; Fu, M. Fingerprinting-Based Indoor Localization Using Interpolated Preprocessed CSI Phases and Bayesian Tracking. Sensors 2020, 20, 2854. [Google Scholar] [CrossRef] [Scilit]
- Thrun, S. Probabilistic robotics. Commun. ACM 2002, 45, 52–57. [Google Scholar] [CrossRef] [Scilit]
- Arulampalam, M.S.; Maskell, S.; Gordon, N.; Clapp, T. A tutorial on particle filters for online nonlinear/non-Gaussian Bayesian tracking. IEEE Trans. Signal Process. 2002, 50, 174–188. [Google Scholar] [CrossRef] [Scilit]
- Wu, K.; Xiao, J.; Yi, Y.; Chen, D.; Luo, X.; Ni, L.M. CSI-based indoor localization. IEEE Trans. Parallel Distrib. Syst. 2012, 24, 1300–1309. [Google Scholar] [CrossRef] [Scilit]
- Wang, X.; Gao, L.; Mao, S.; Pandey, S. DeepFi: Deep learning for indoor fingerprinting using channel state information. In Proceedings of the 2015 IEEE Wireless Communications and Networking Conference (WCNC), New Orleans, LA, USA, 9–12 March 2015; pp. 1666–1671. [Google Scholar]
- Wang, X.; Gao, L.; Mao, S. CSI phase fingerprinting for indoor localization with a deep learning approach. IEEE Internet Things J. 2016, 3, 1113–1123. [Google Scholar] [CrossRef] [Scilit]
- Xie, Y.; Li, Z.; Li, M. Precise power delay profiling with commodity Wi-Fi. IEEE Trans. Mob. Comput. 2018, 18, 1342–1355. [Google Scholar] [CrossRef] [Scilit]
- Silverman, B.W. Density Estimation for Statistics and Data Analysis; CRC Press: Boca Raton, FL, USA, 1986; Volume 26. [Google Scholar]
- 3GPP. TR38.855. In Study on NR Positioning Support (Release 16); 3rd Generation Partnership Project (3GPP): Sophia Antipolis, France, 2019. [Google Scholar]
- Devore, J.L.; Berk, K.N. Modern Mathematical Statistics with Applications; Springer: New York, NY, USA, 2012. [Google Scholar]
- Petersen, K.; Pedersen, M. The Matrix Cookbook; Technical Manual; Technical University of Denmark: Lyngby, Denmark, 2008. [Google Scholar]



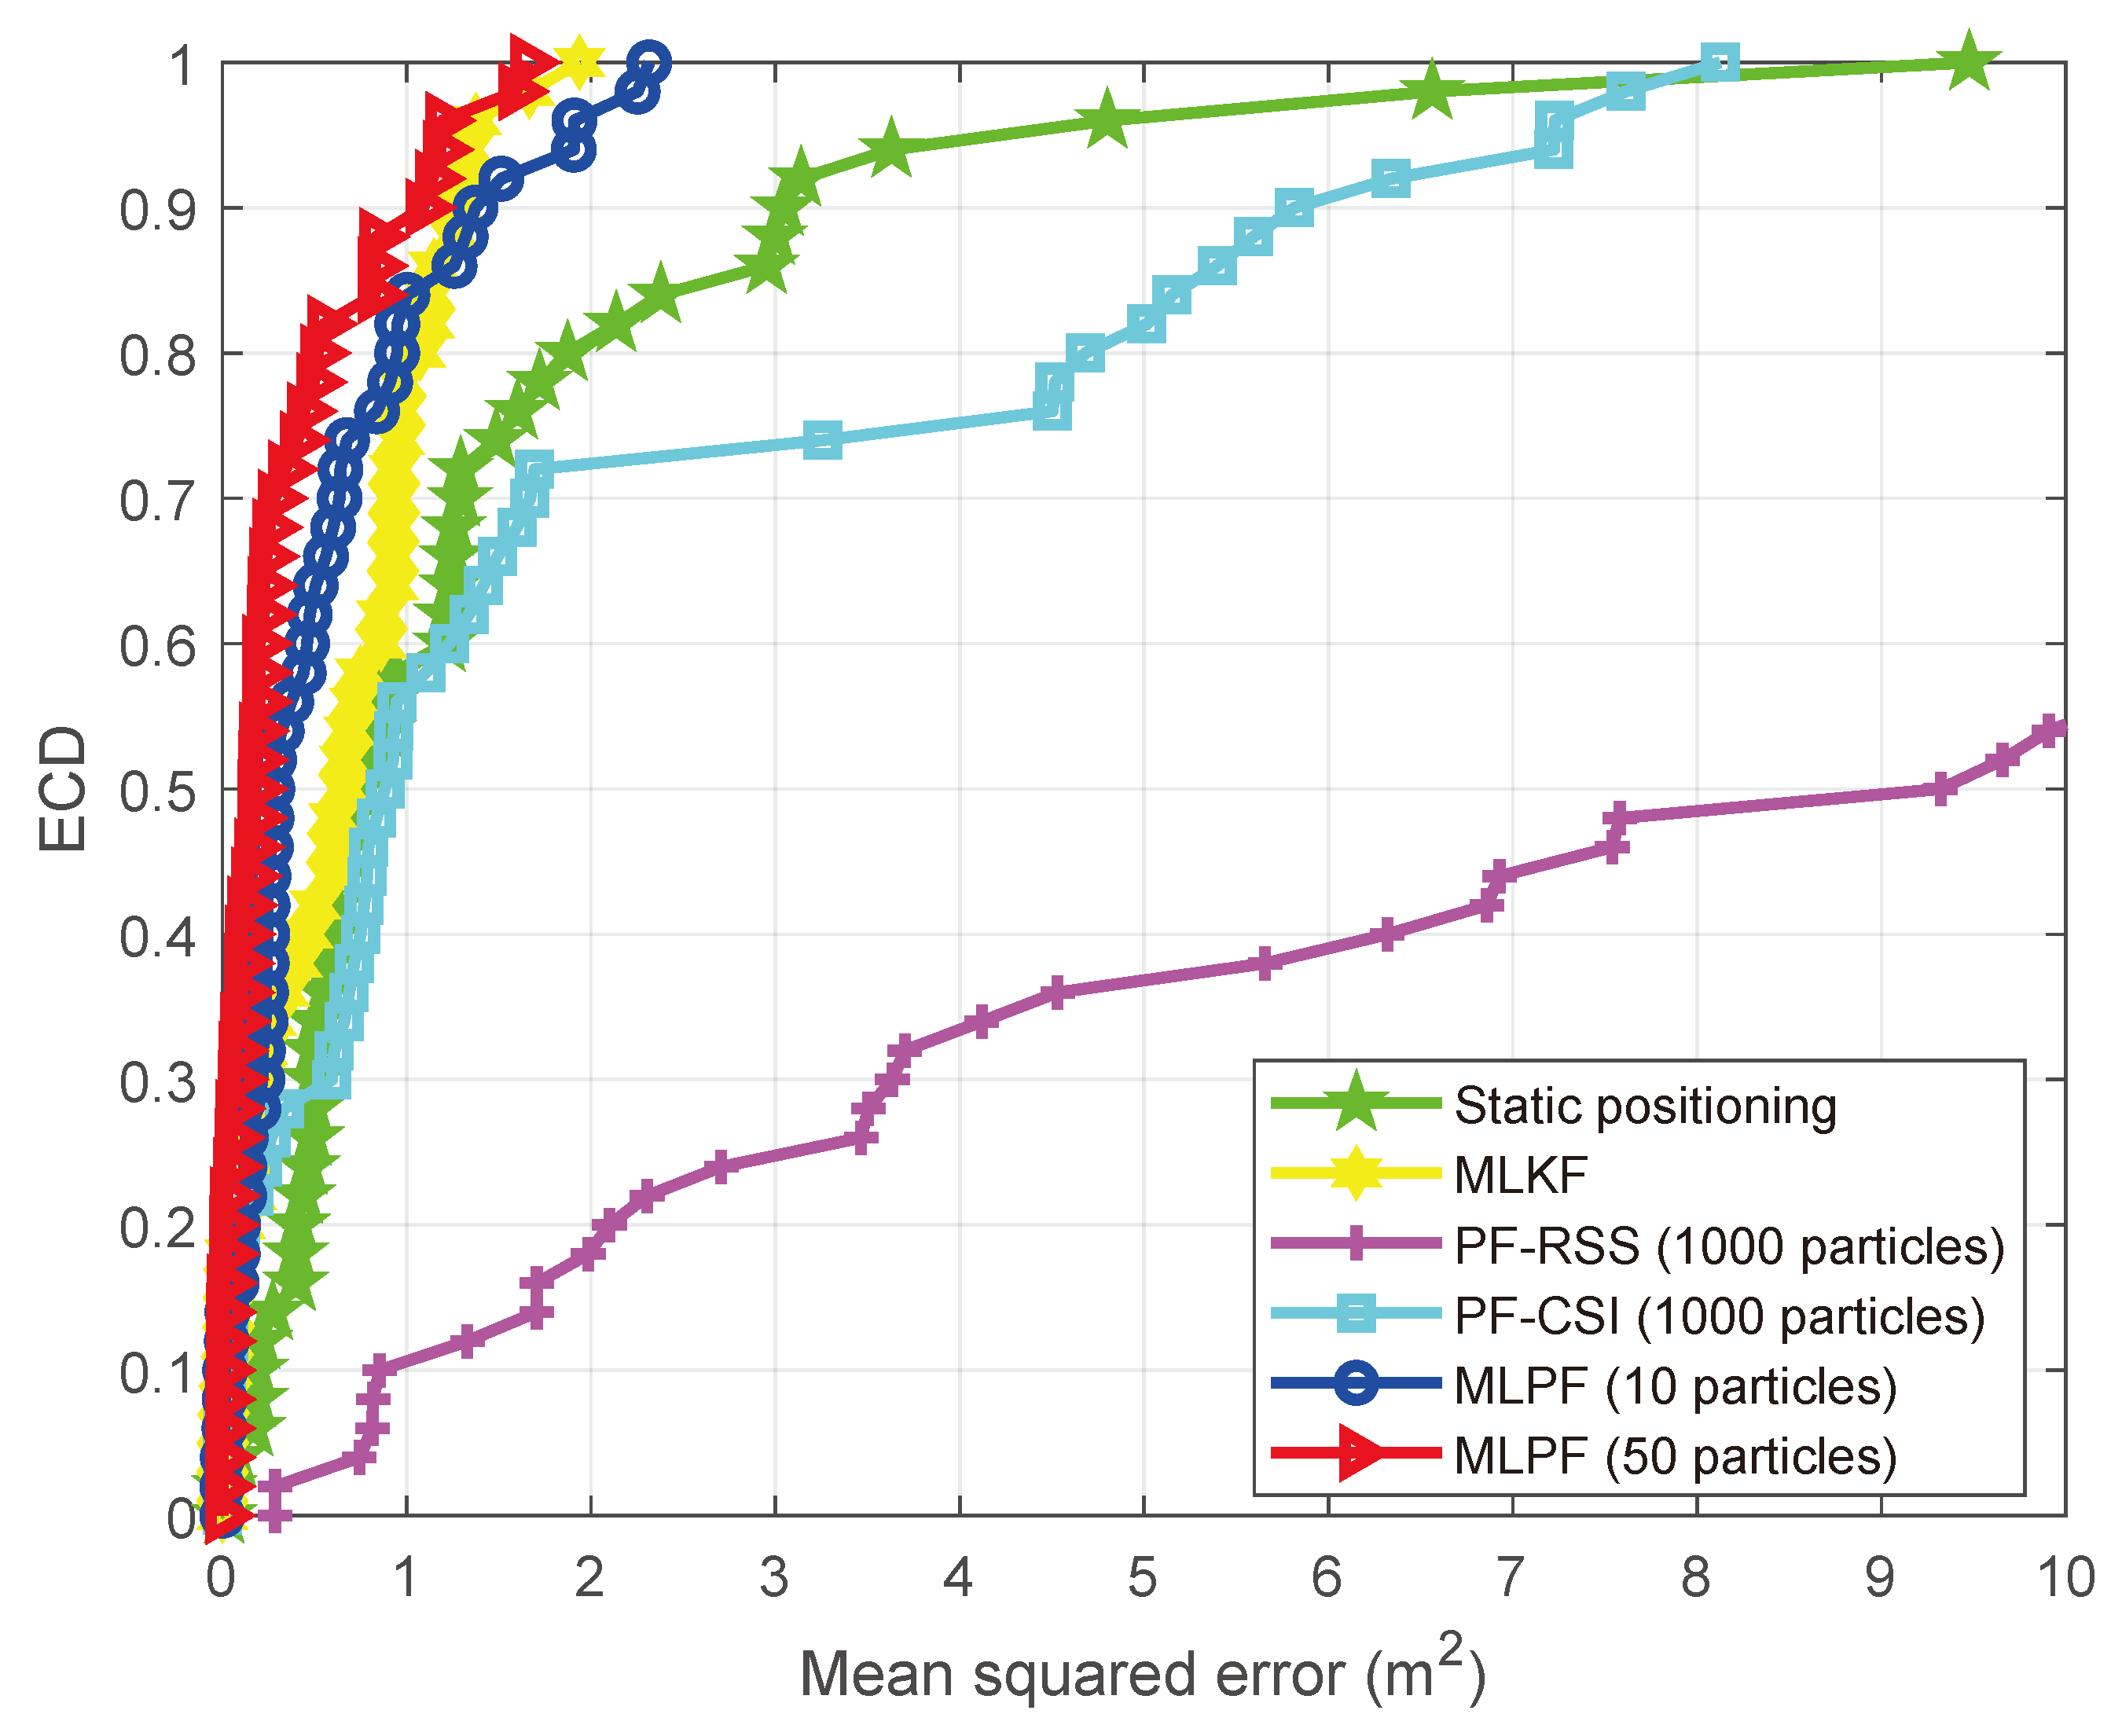
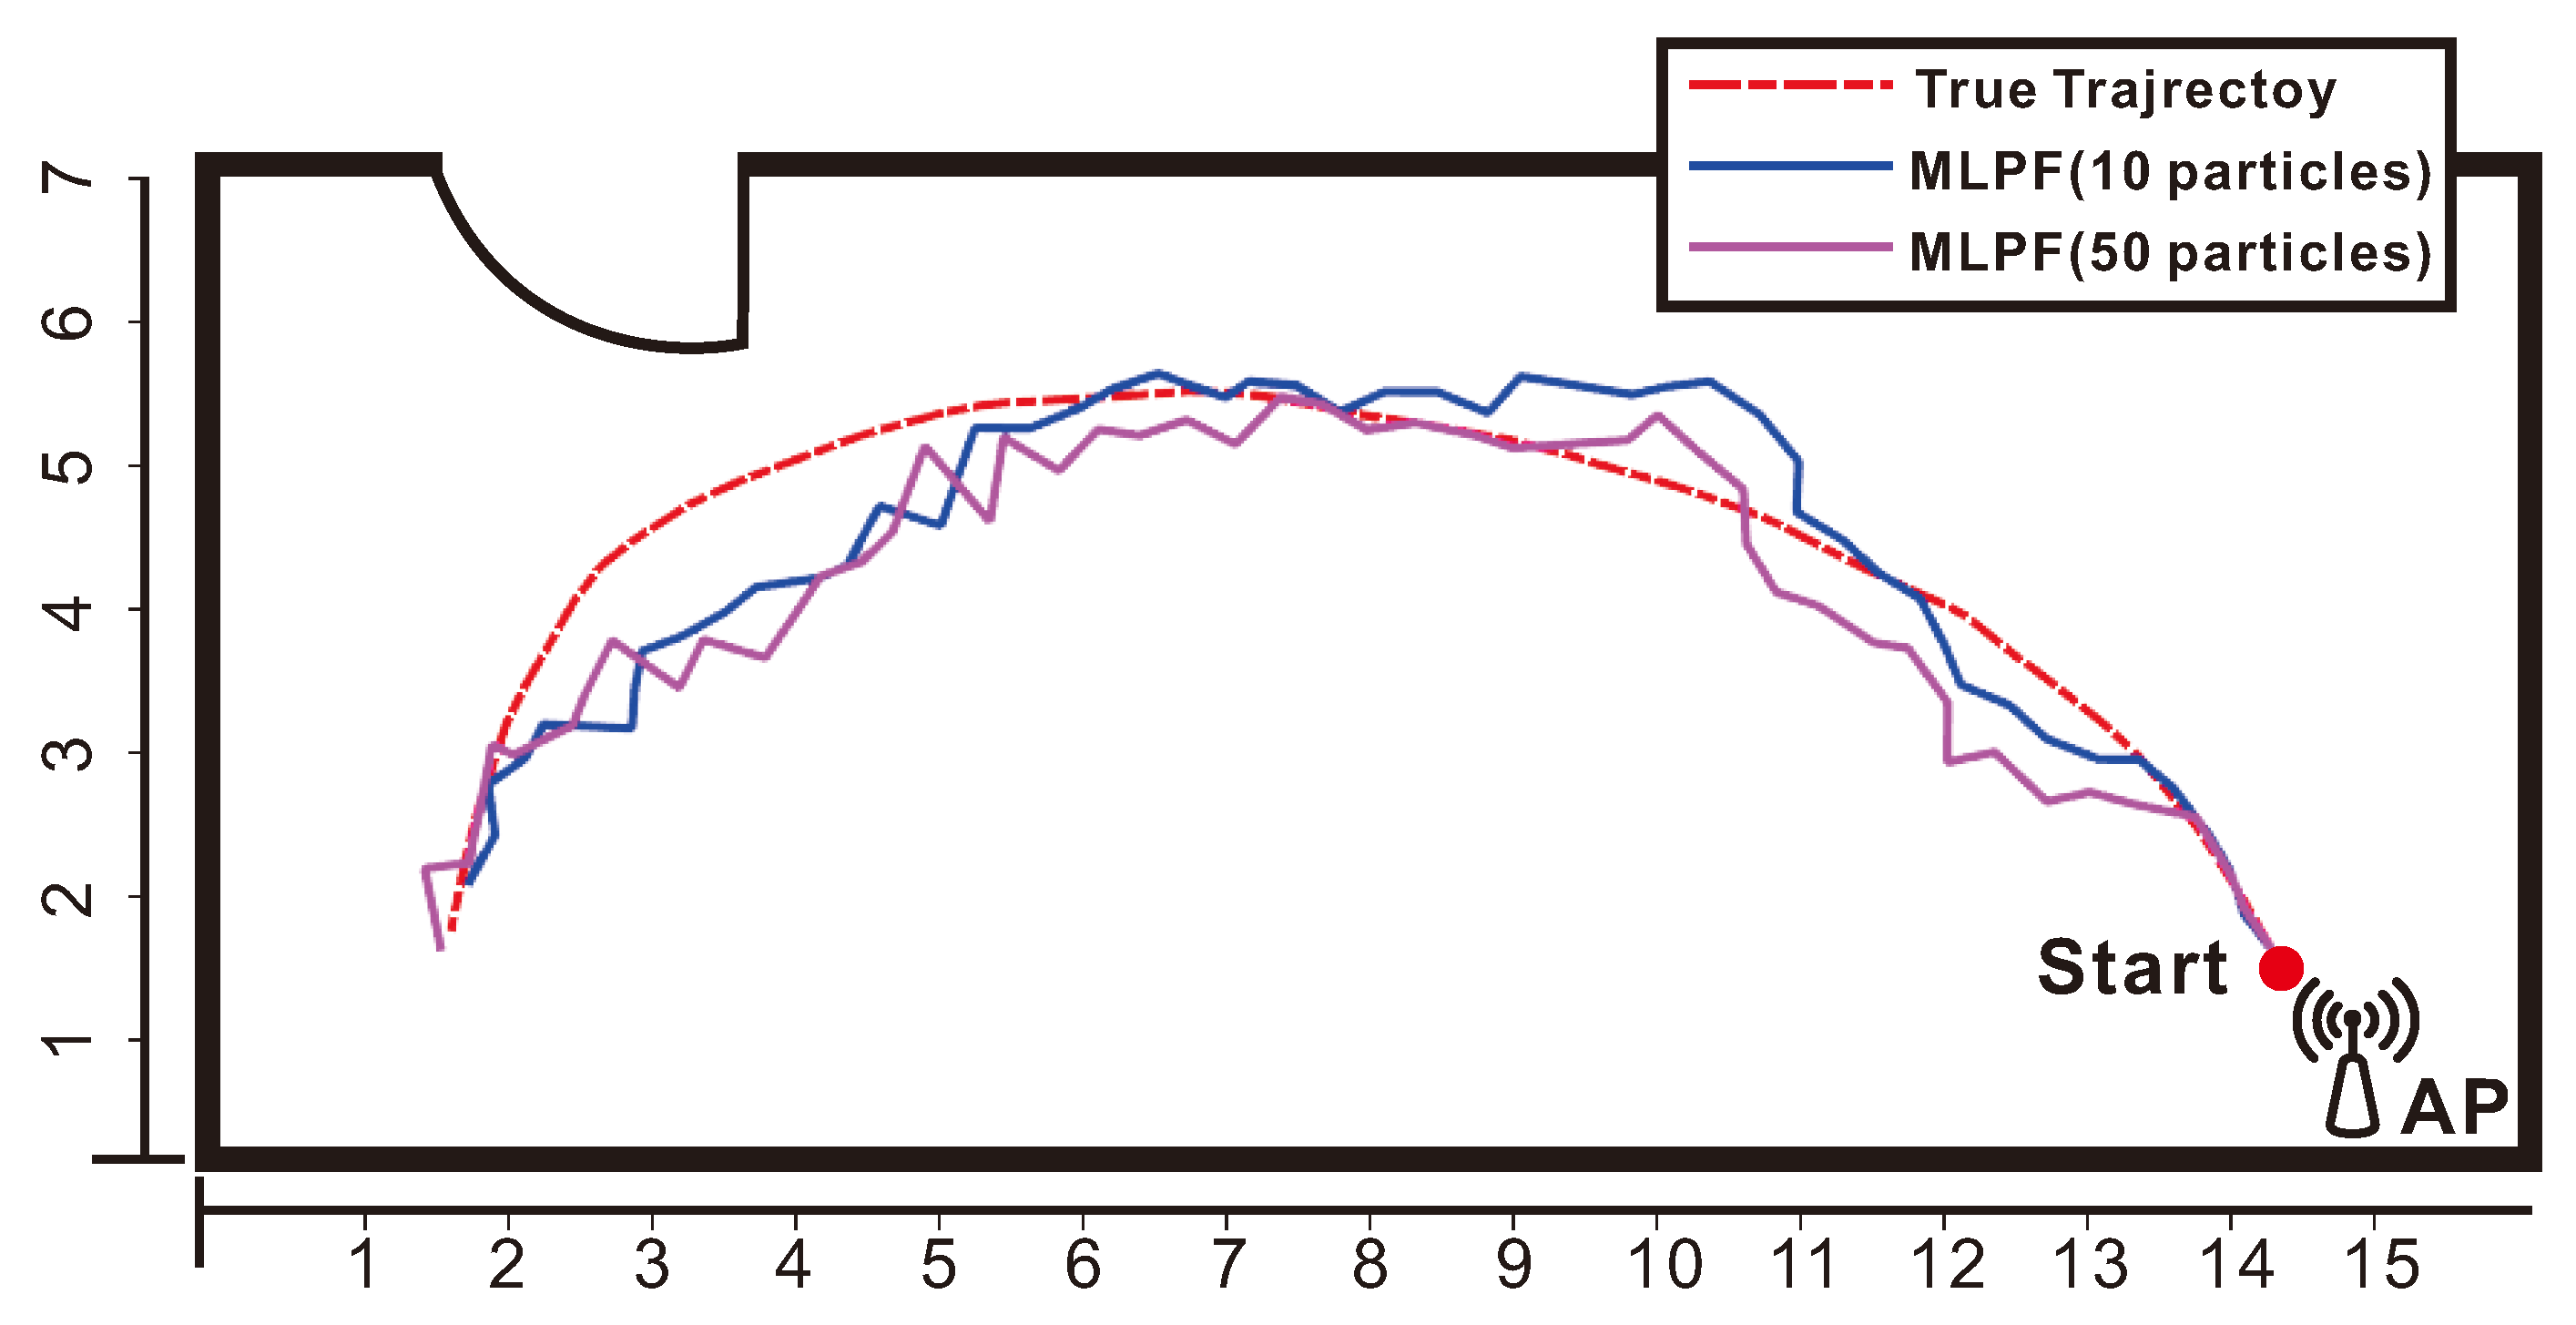
| Methods | Mean Squared Error [m] | 90% Acc. [m] |
|---|---|---|
| Static positioning | 1.4153 | 3.0437 |
| MLKF | 0.6506 | 1.2848 |
| PF-RSS (1000 particles) | 12.1310 | 28.3569 |
| PF-CSI (1000 particles) | 2.0834 | 5.8151 |
| MLPF (10 particles) | 0.5607 | 1.3724 |
| MLPF (50 particles) | 0.3370 | 1.0891 |
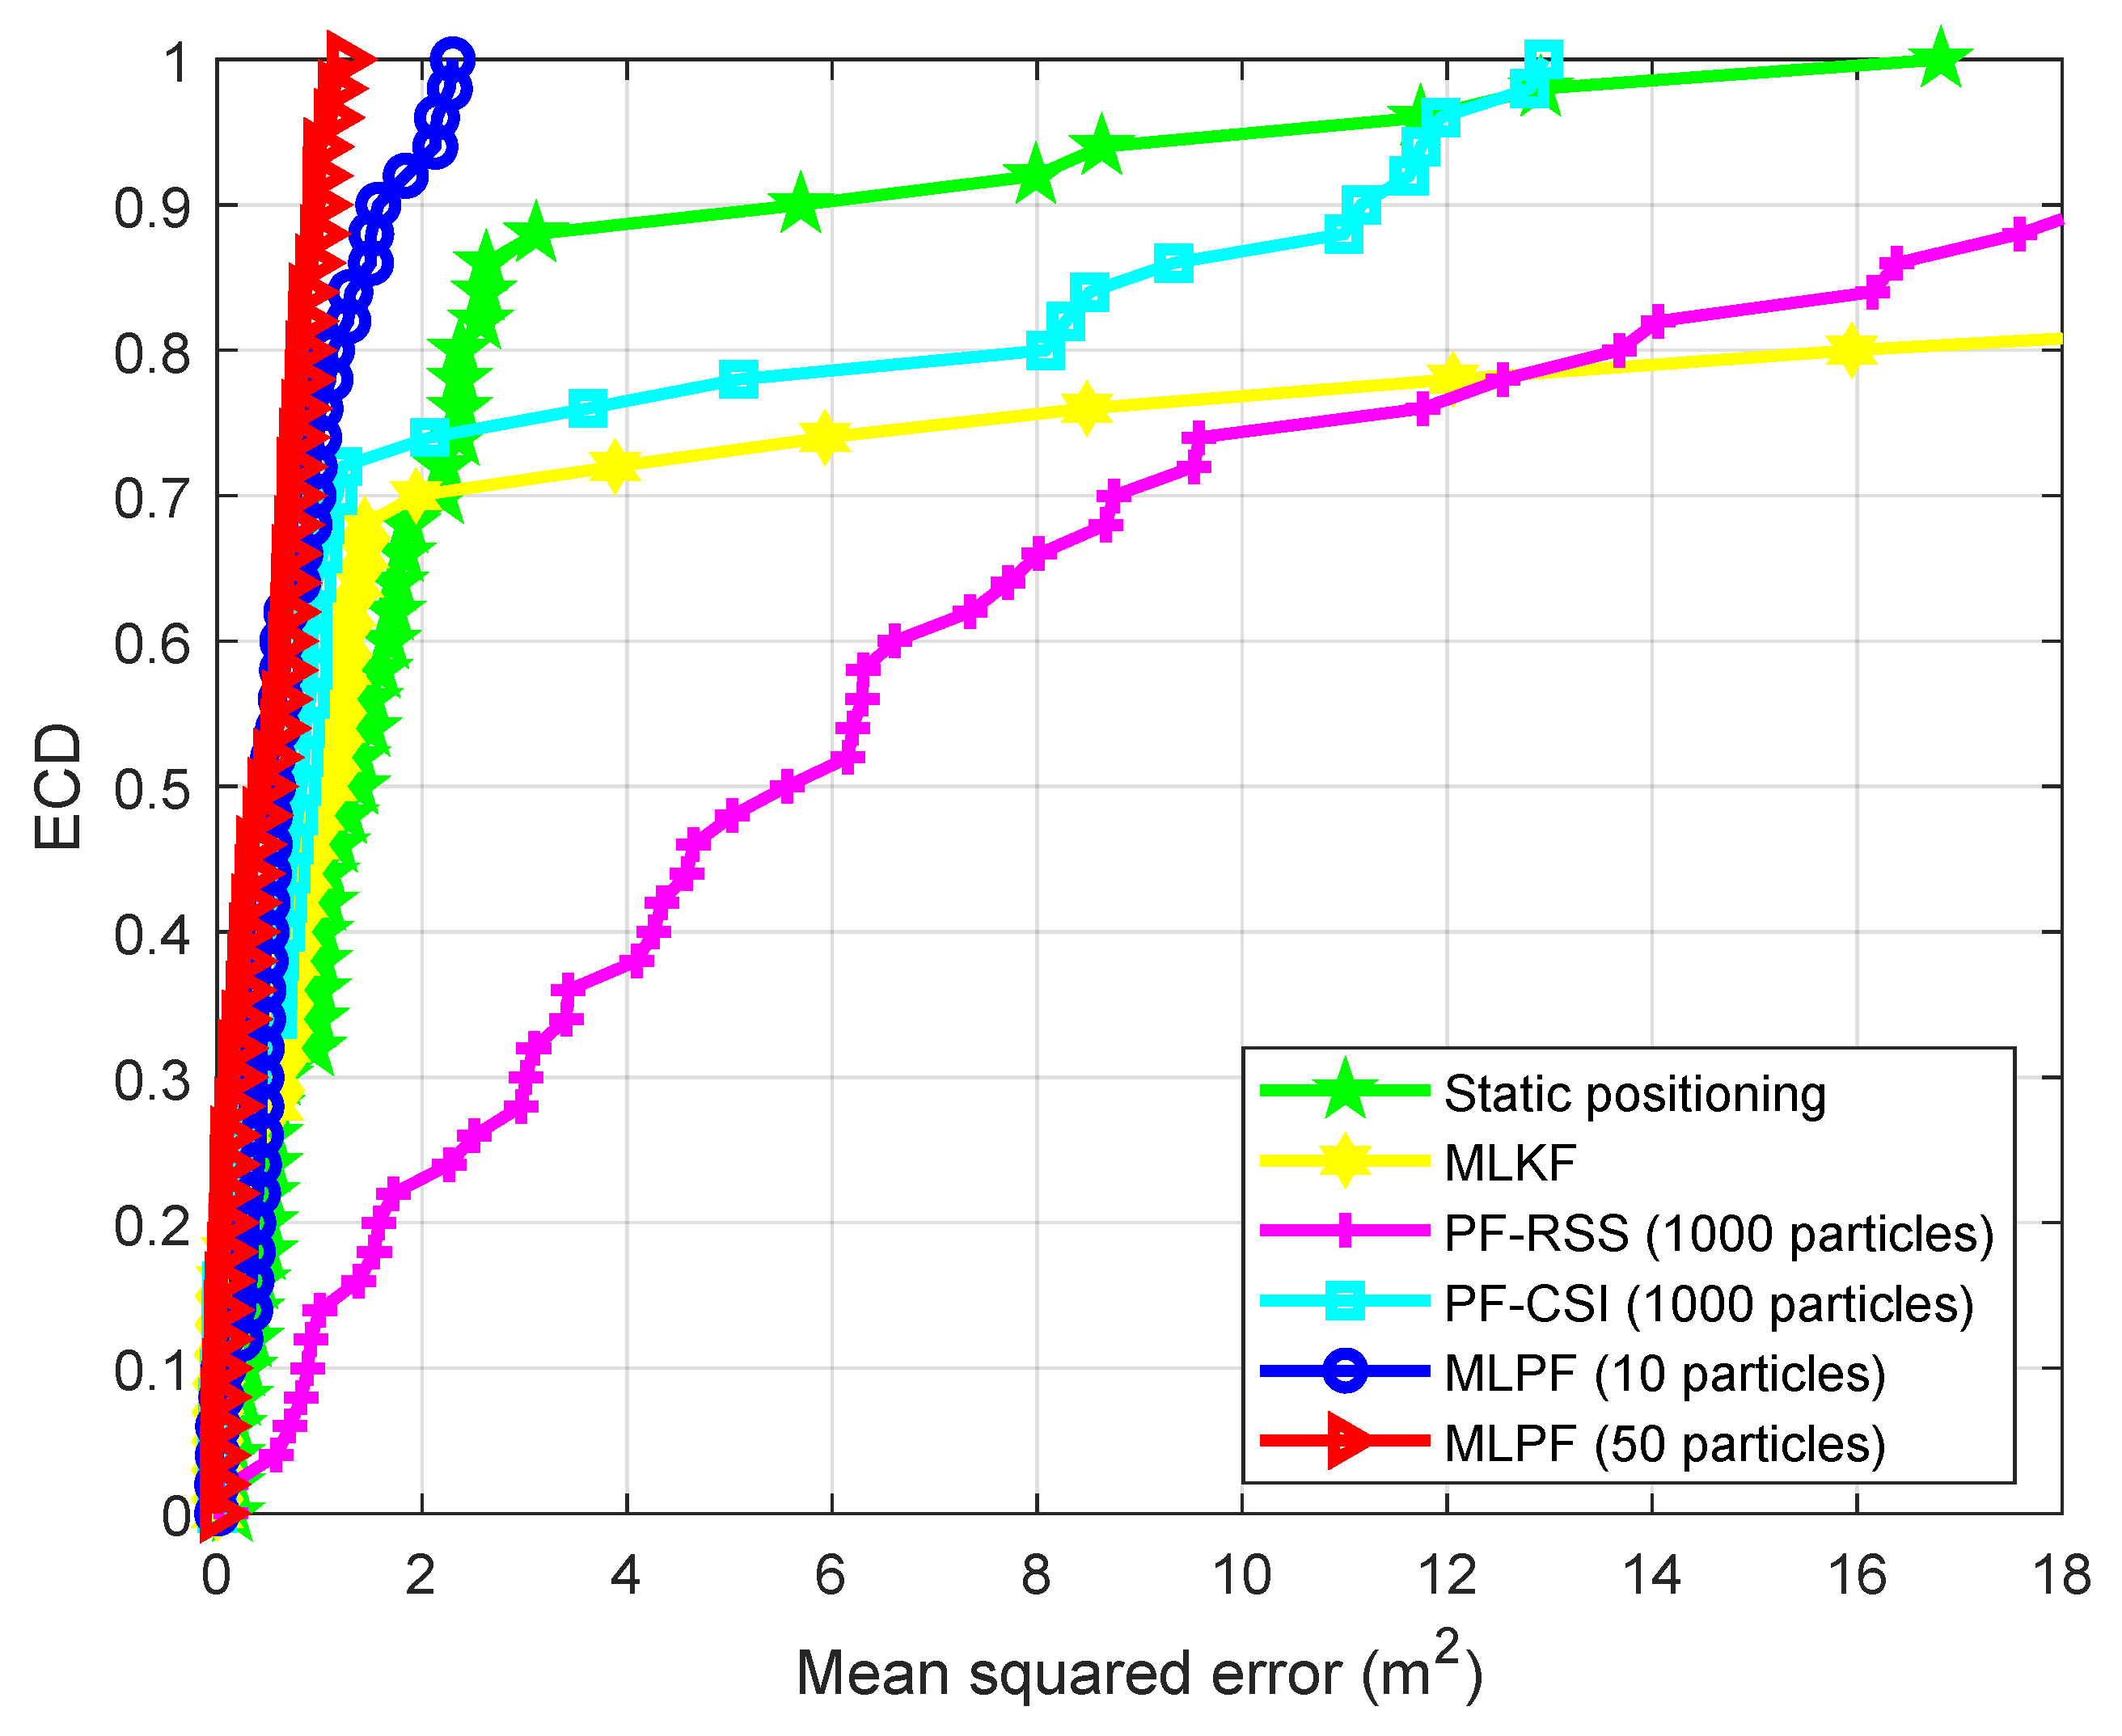
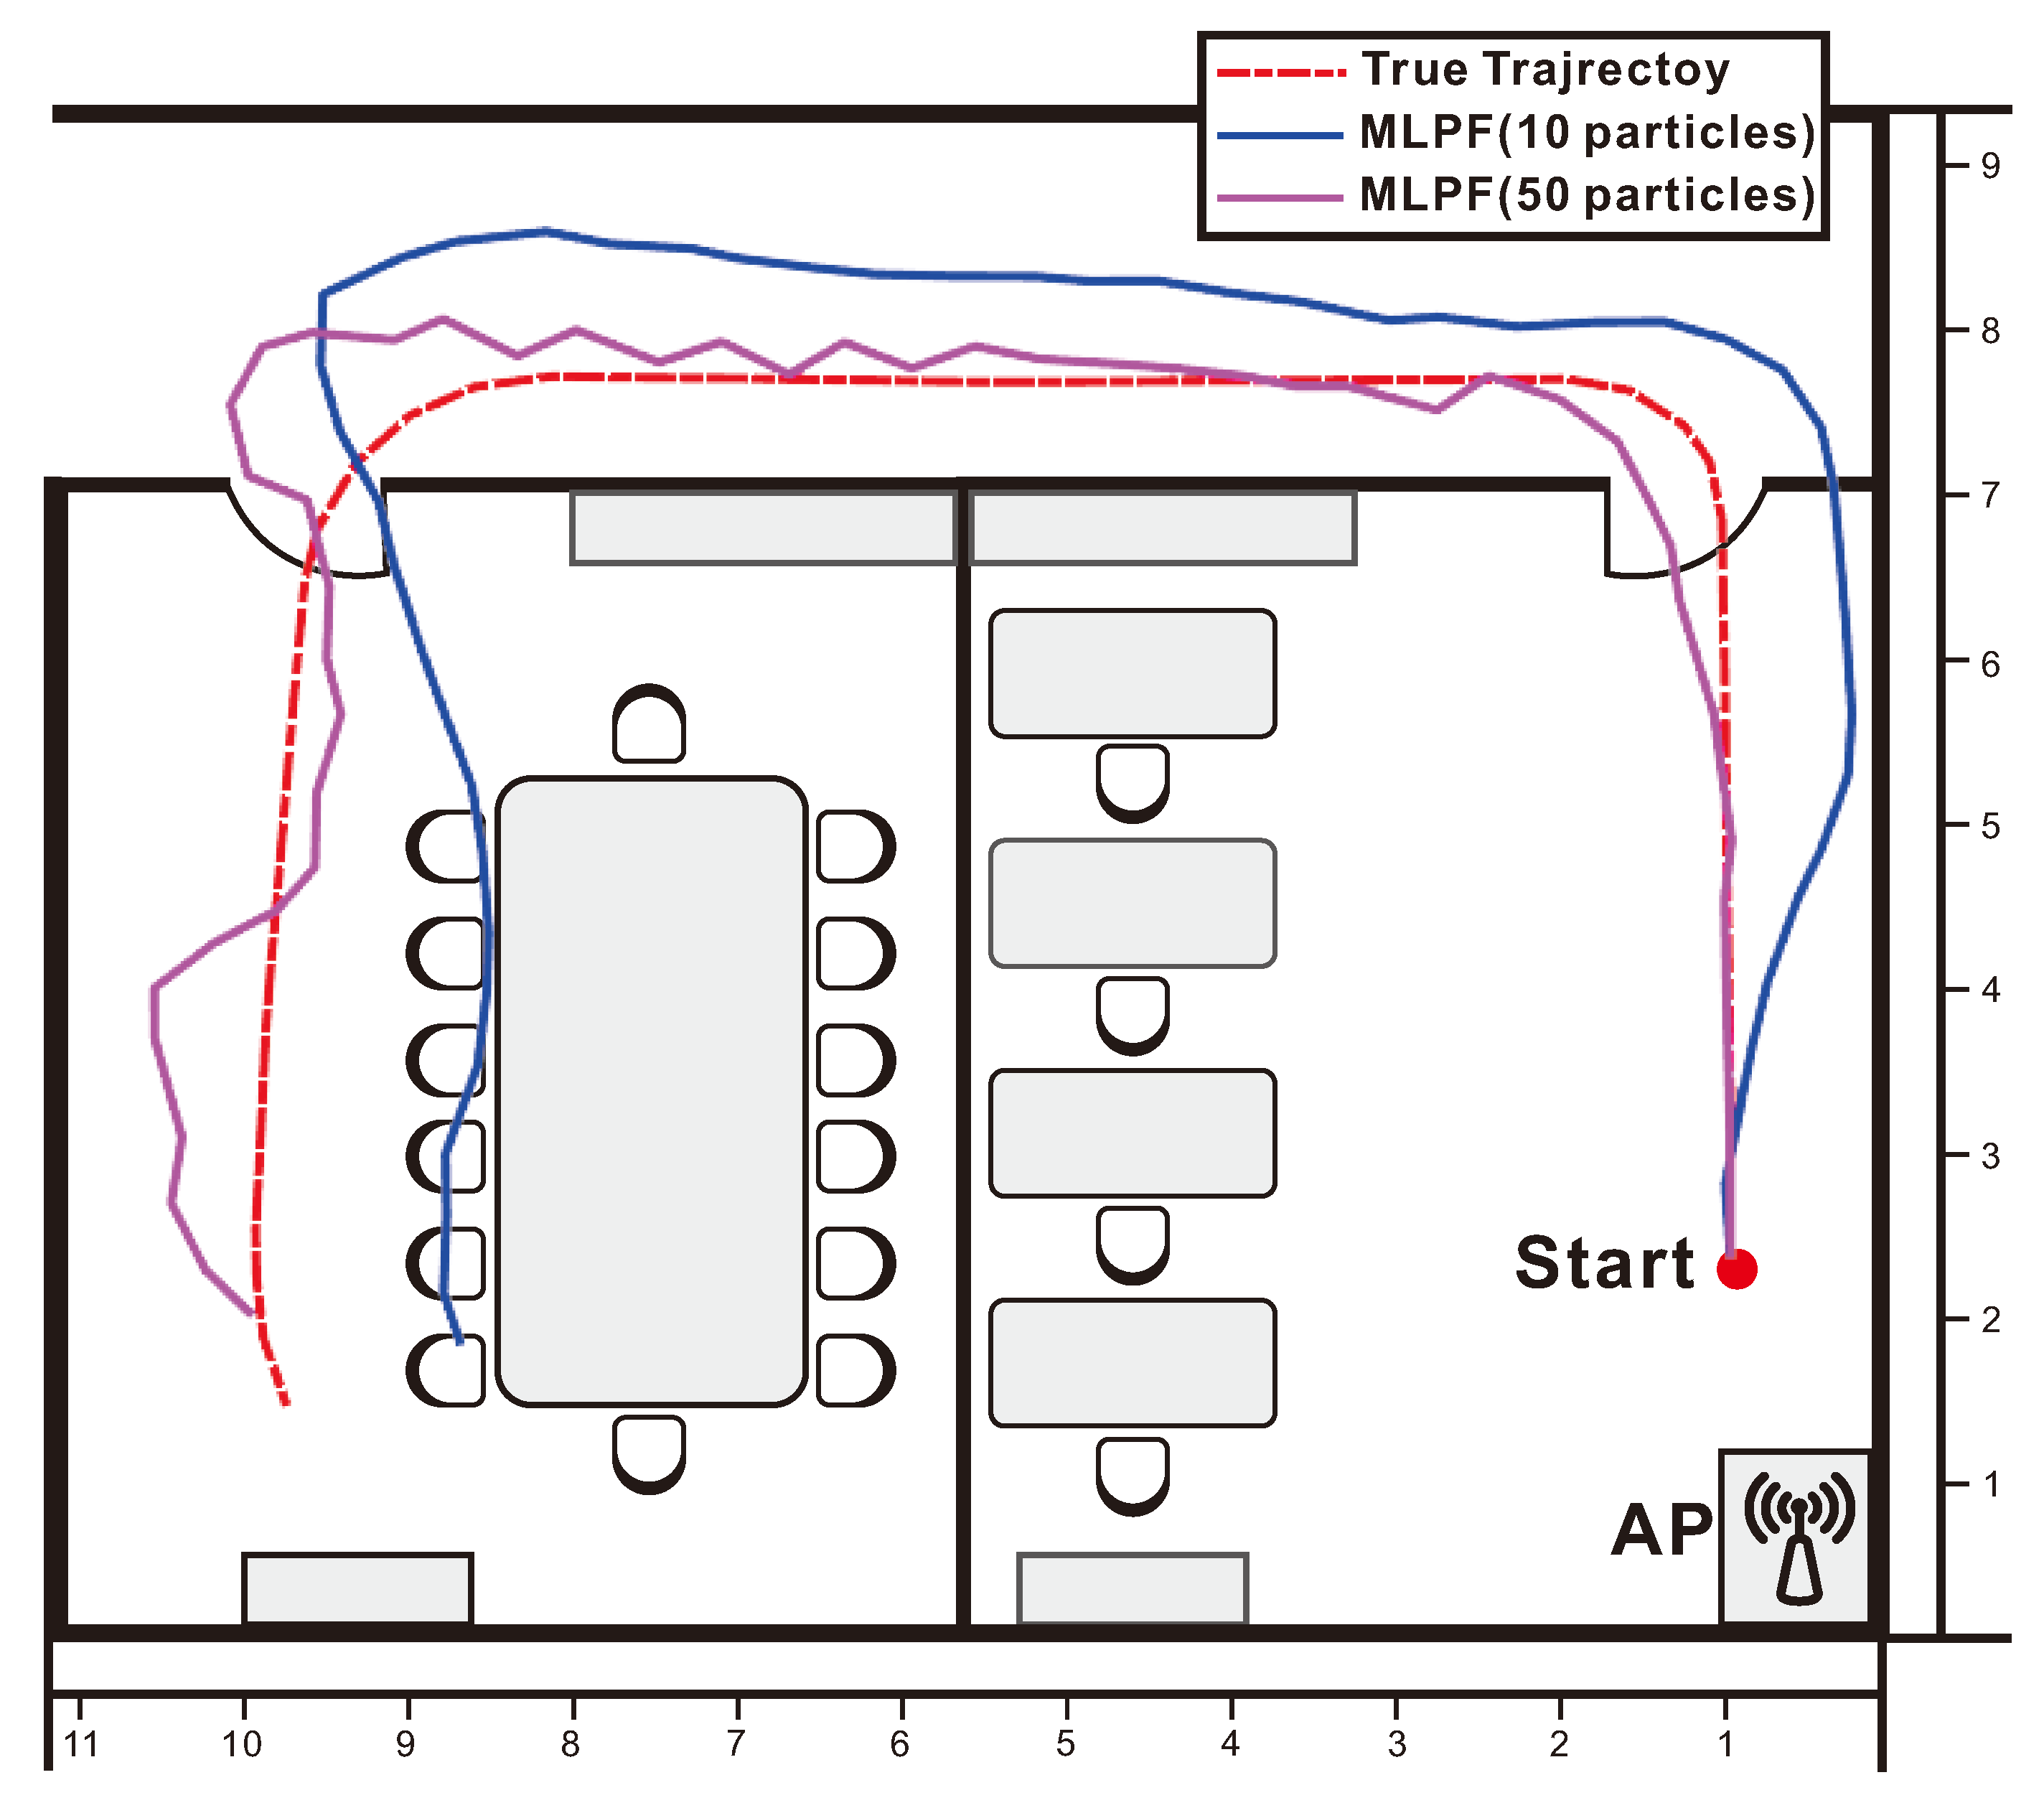
| Methods | Mean Squared Error [m] | 90% Acc. [m] |
|---|---|---|
| Static positioning | 2.3962 | 5.6935 |
| MLKF | 11.7255 | 50.8279 |
| PF-RSS (1000 particles) | 8.2366 | 18.3872 |
| PF-CSI (1000 particles) | 2.9418 | 11.1606 |
| MLPF (10 particles) | 0.7755 | 1.5712 |
| MLPF (50 particles) | 0.4939 | 0.9970 |
Publisher’s Note: MDPI stays neutral with regard to jurisdictional claims in published maps and institutional affiliations. |
© 2021 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (http://creativecommons.org/licenses/by/4.0/).
Share and Cite
Wang, W.; Marelli, D.; Fu, M. Dynamic Indoor Localization Using Maximum Likelihood Particle Filtering. Sensors 2021, 21, 1090. https://doi.org/10.3390/s21041090
Wang W, Marelli D, Fu M. Dynamic Indoor Localization Using Maximum Likelihood Particle Filtering. Sensors. 2021; 21(4):1090. https://doi.org/10.3390/s21041090
Chicago/Turabian StyleWang, Wenxu, Damián Marelli, and Minyue Fu. 2021. "Dynamic Indoor Localization Using Maximum Likelihood Particle Filtering" Sensors 21, no. 4: 1090. https://doi.org/10.3390/s21041090
APA StyleWang, W., Marelli, D., & Fu, M. (2021). Dynamic Indoor Localization Using Maximum Likelihood Particle Filtering. Sensors, 21(4), 1090. https://doi.org/10.3390/s21041090