
A CNN-Based Micro-UAV System for Real-Time Flower Detection and Target Approach

 ,
 , , , and
Abstract
1. Introduction
- Micro-Scale Navigation: Demonstration of a micro-UAV platform (<100 mm × 100 mm) capable of navigating the highly confined spaces typical of vertical farms and greenhouses, where larger drones are impractical.
- Real-Time CNN Integration: Implementation of a custom Sequential CNN architecture for real-time binary classification (‘flower’ vs. ‘not flower’) directly integrated with the micro-UAV’s autonomous flight system.
- Hardware Performance Benchmarking: A comparative analysis revealing that specialized onboard image-processing hardware significantly outperforms standard webcams in terms of detection speed and accuracy.
- Operational Optimization: Empirical determination of the optimal operational range ( cm to cm) for effective flower detection, providing a foundation for future autonomous pollination strategies.
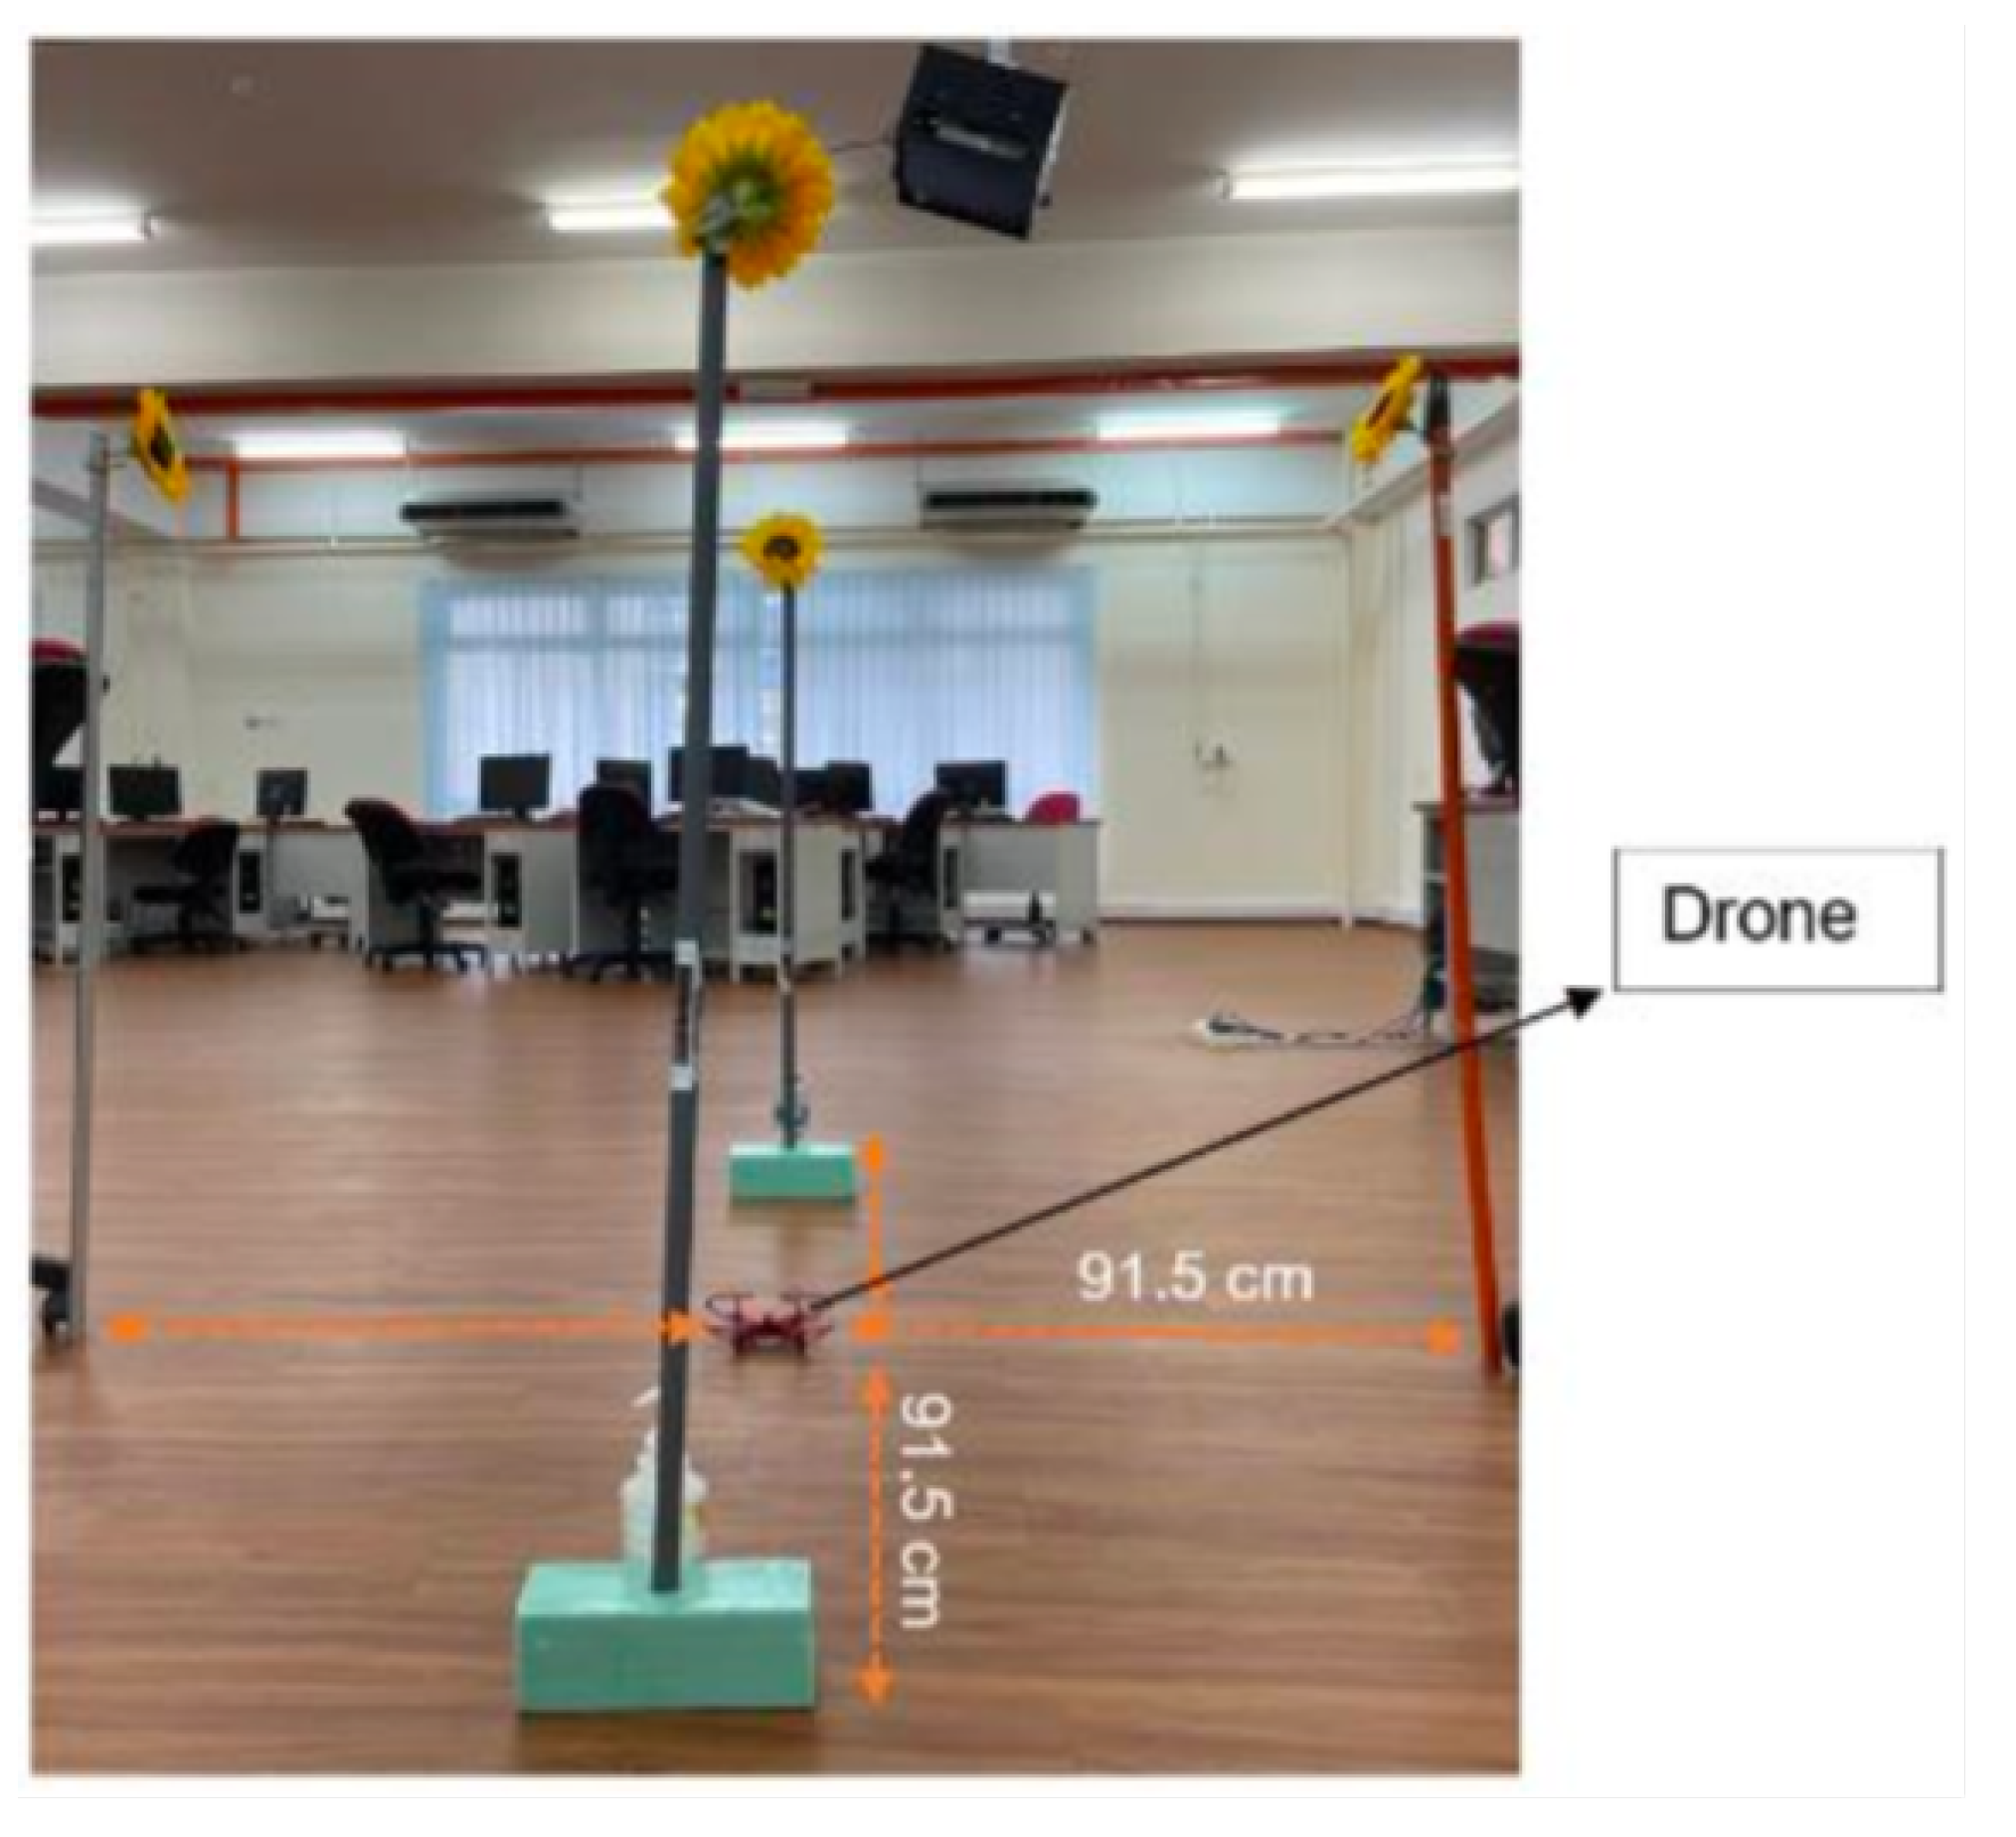
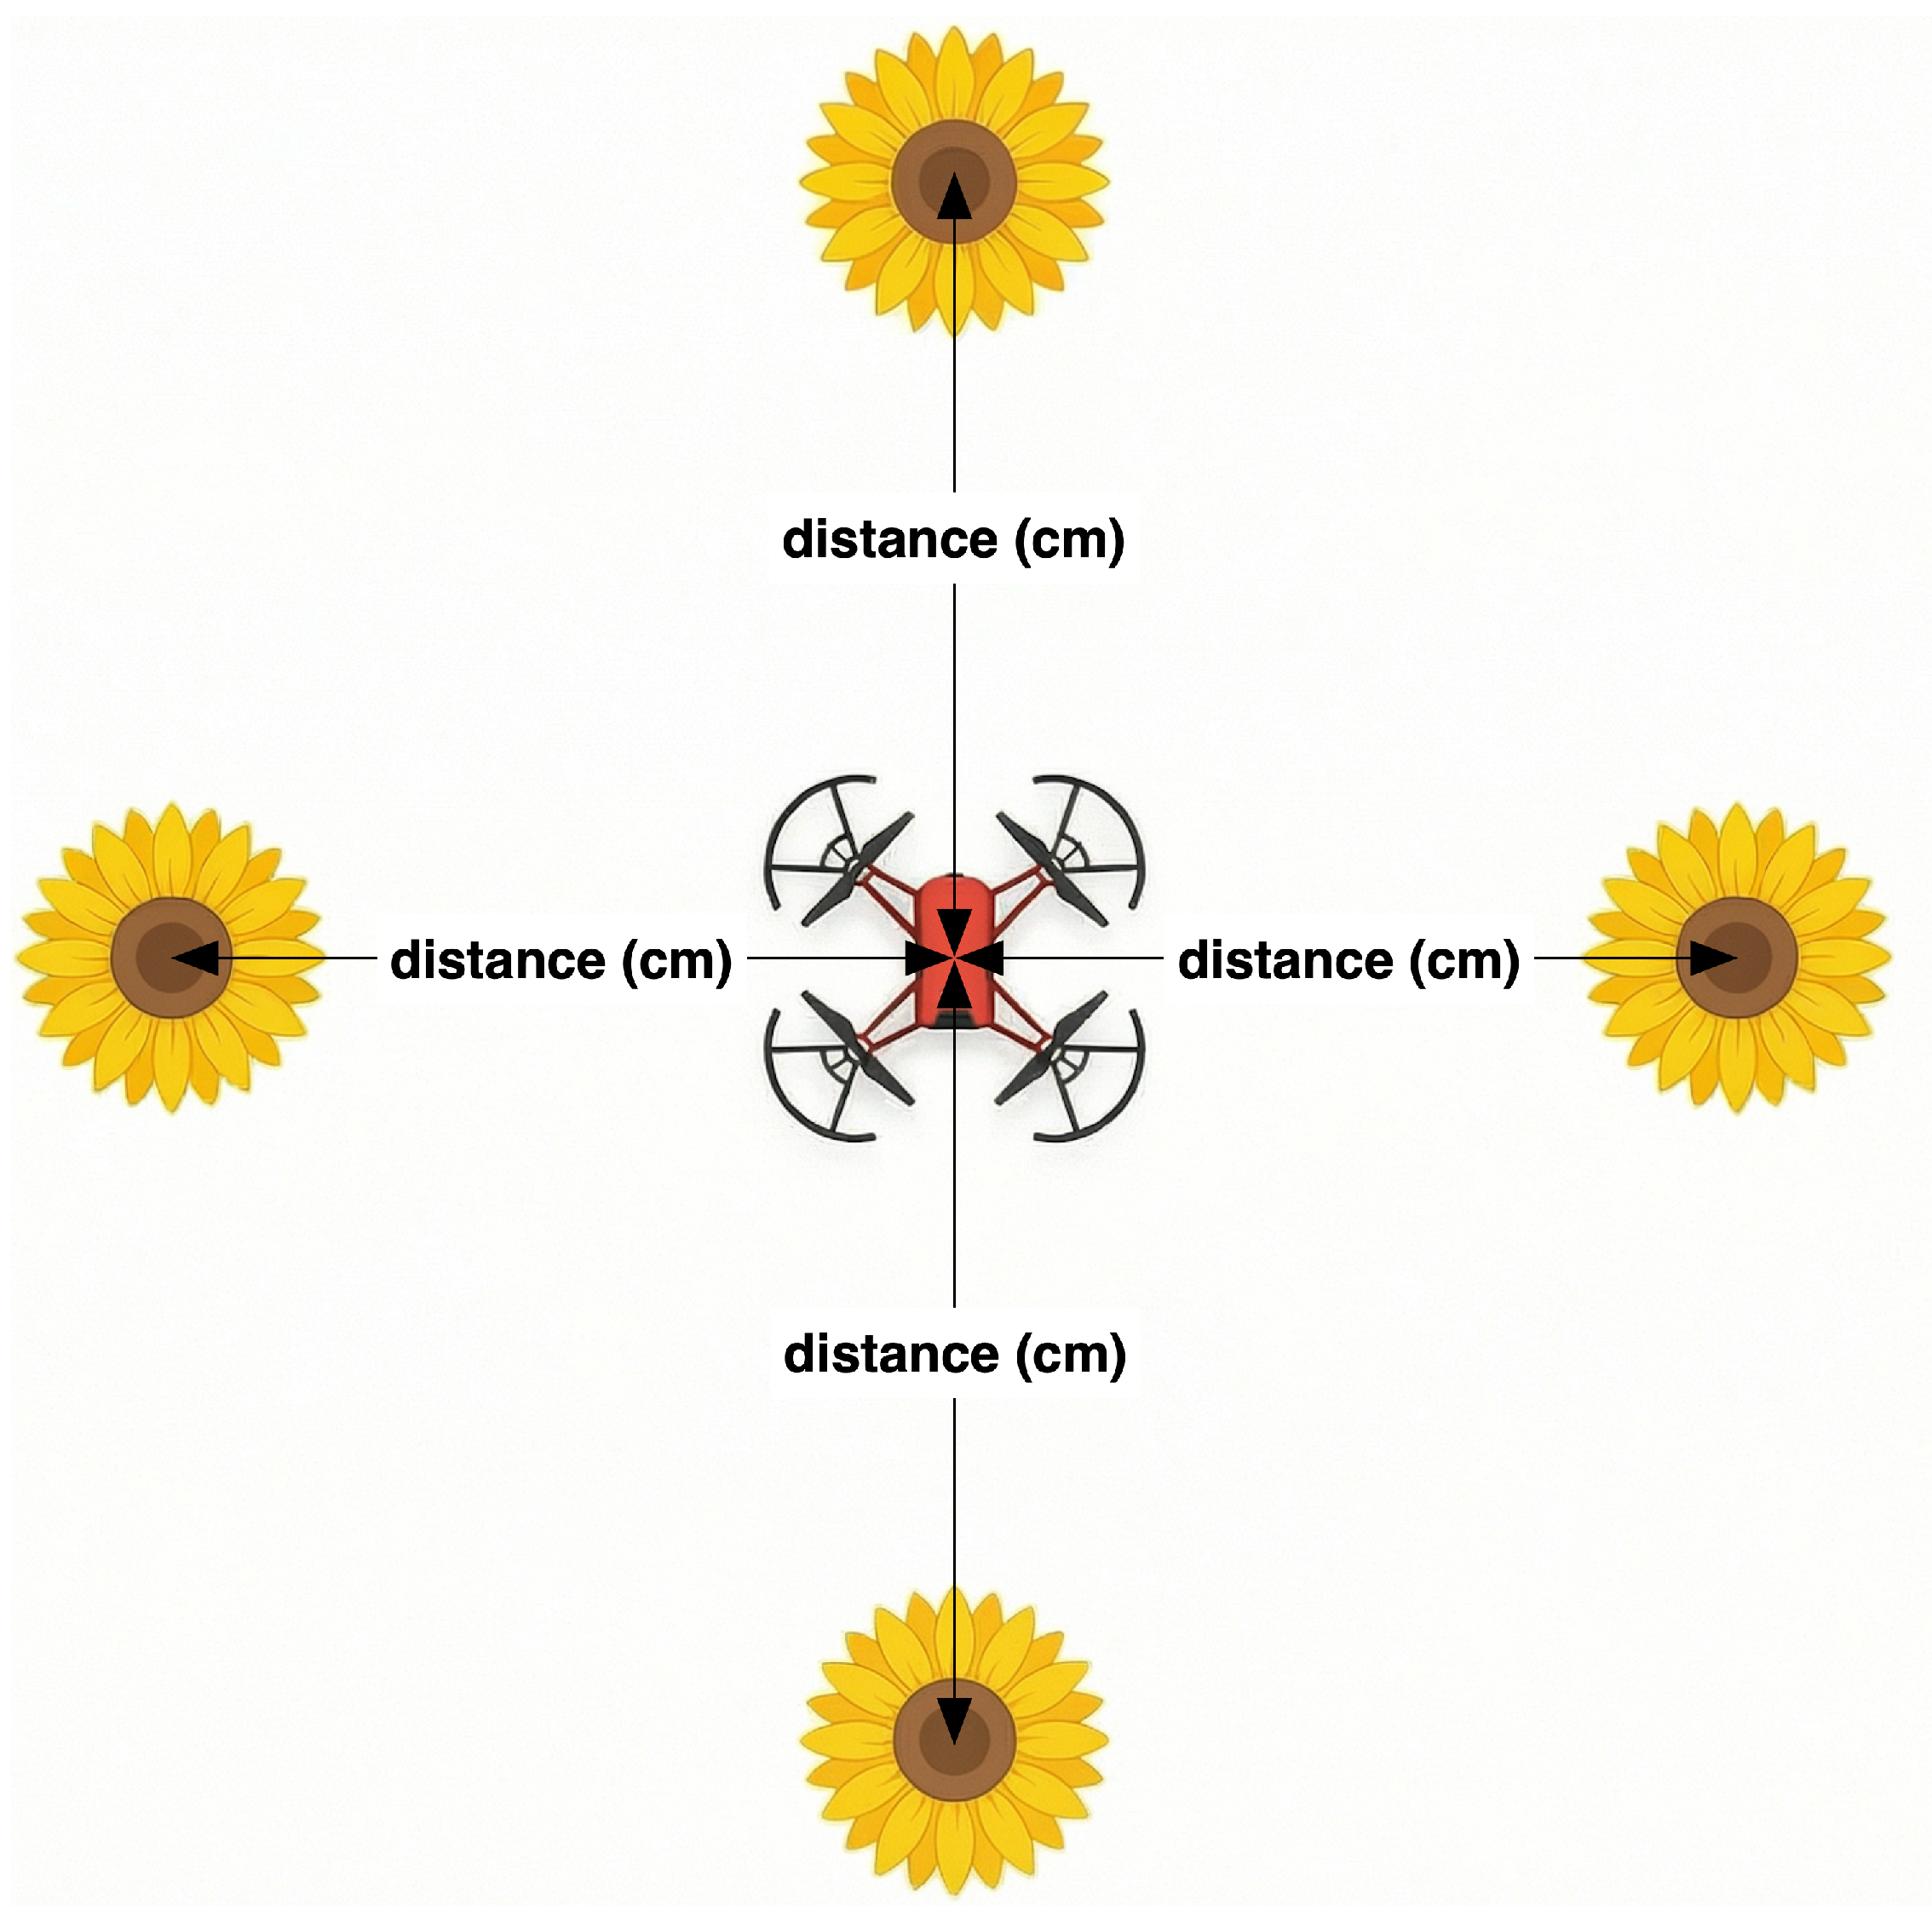
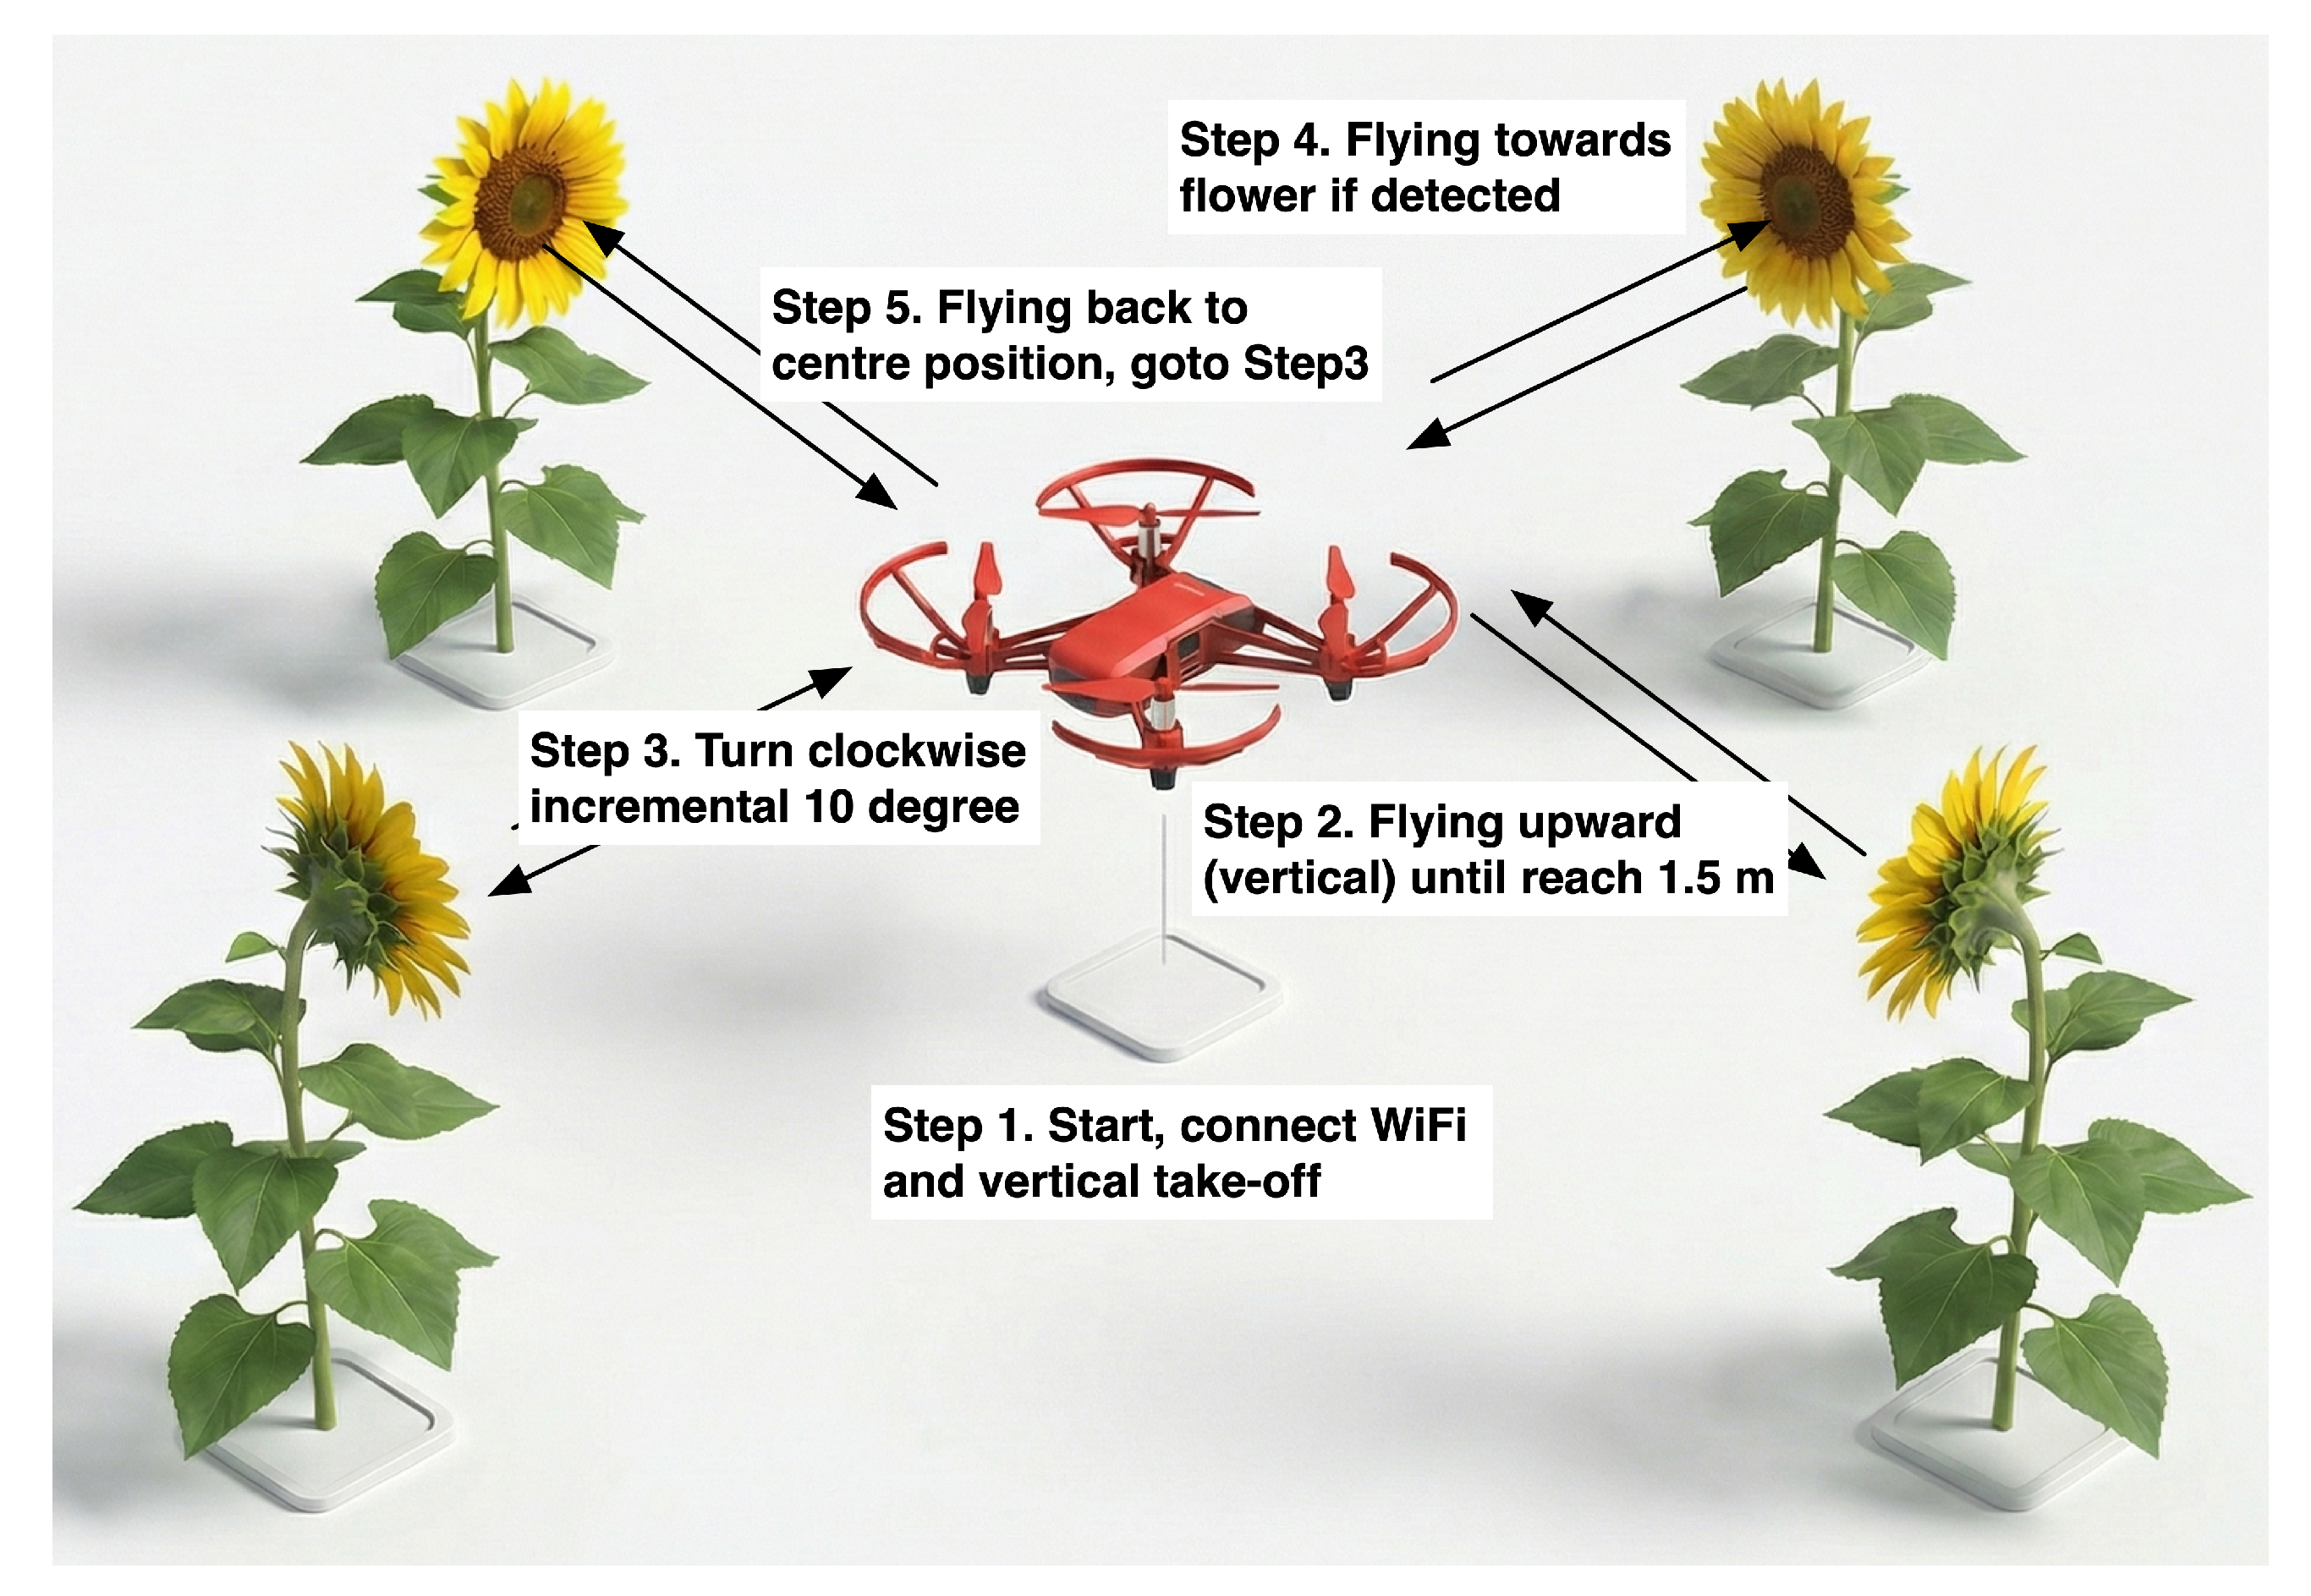
- Autonomous Flight Validation: Validation of a pre-programmed ‘cross’-shaped flight pattern that enables the drone to systematically identify and approach multiple targets without human intervention.
2. Related Works
2.1. Agriculture Micro-UAV
2.2. Potential of Autonomous Pollinator Drone
2.3. Simultaneous Navigation and Flower Recognition
2.4. Drone-Based Pollination
3. Experimental Setup
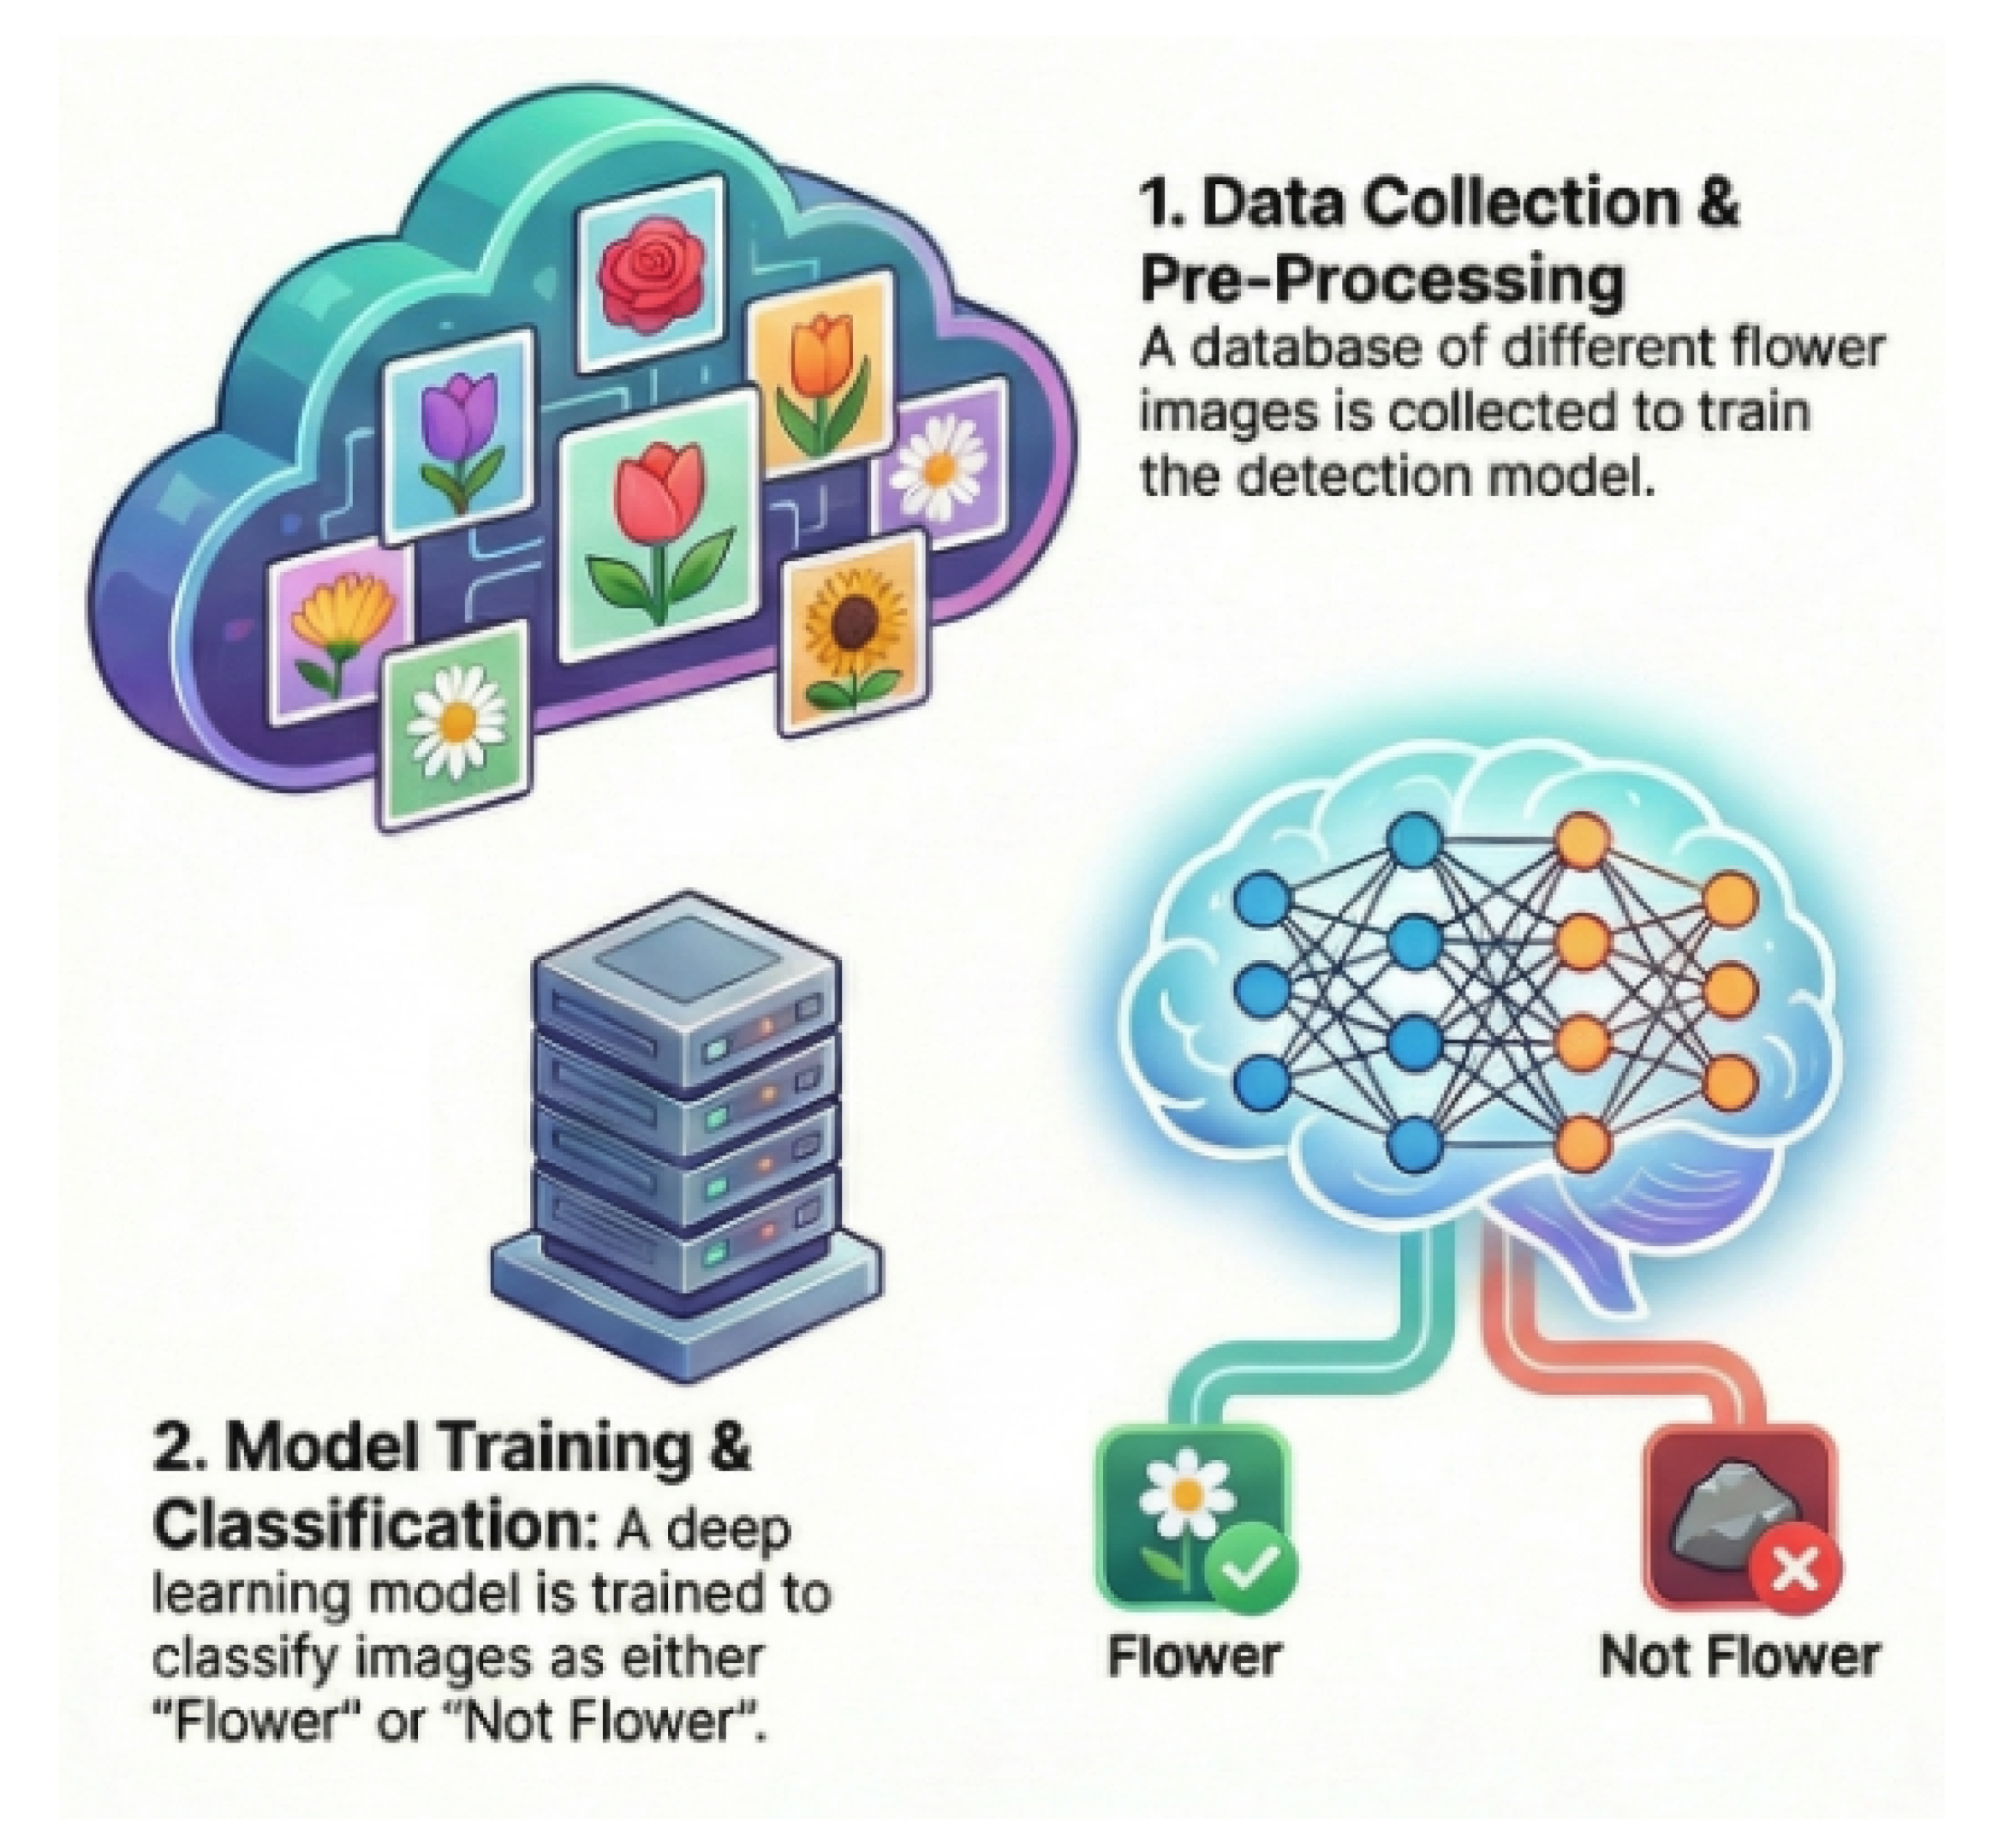
3.1. AI Binary Classification for Flower Recognition
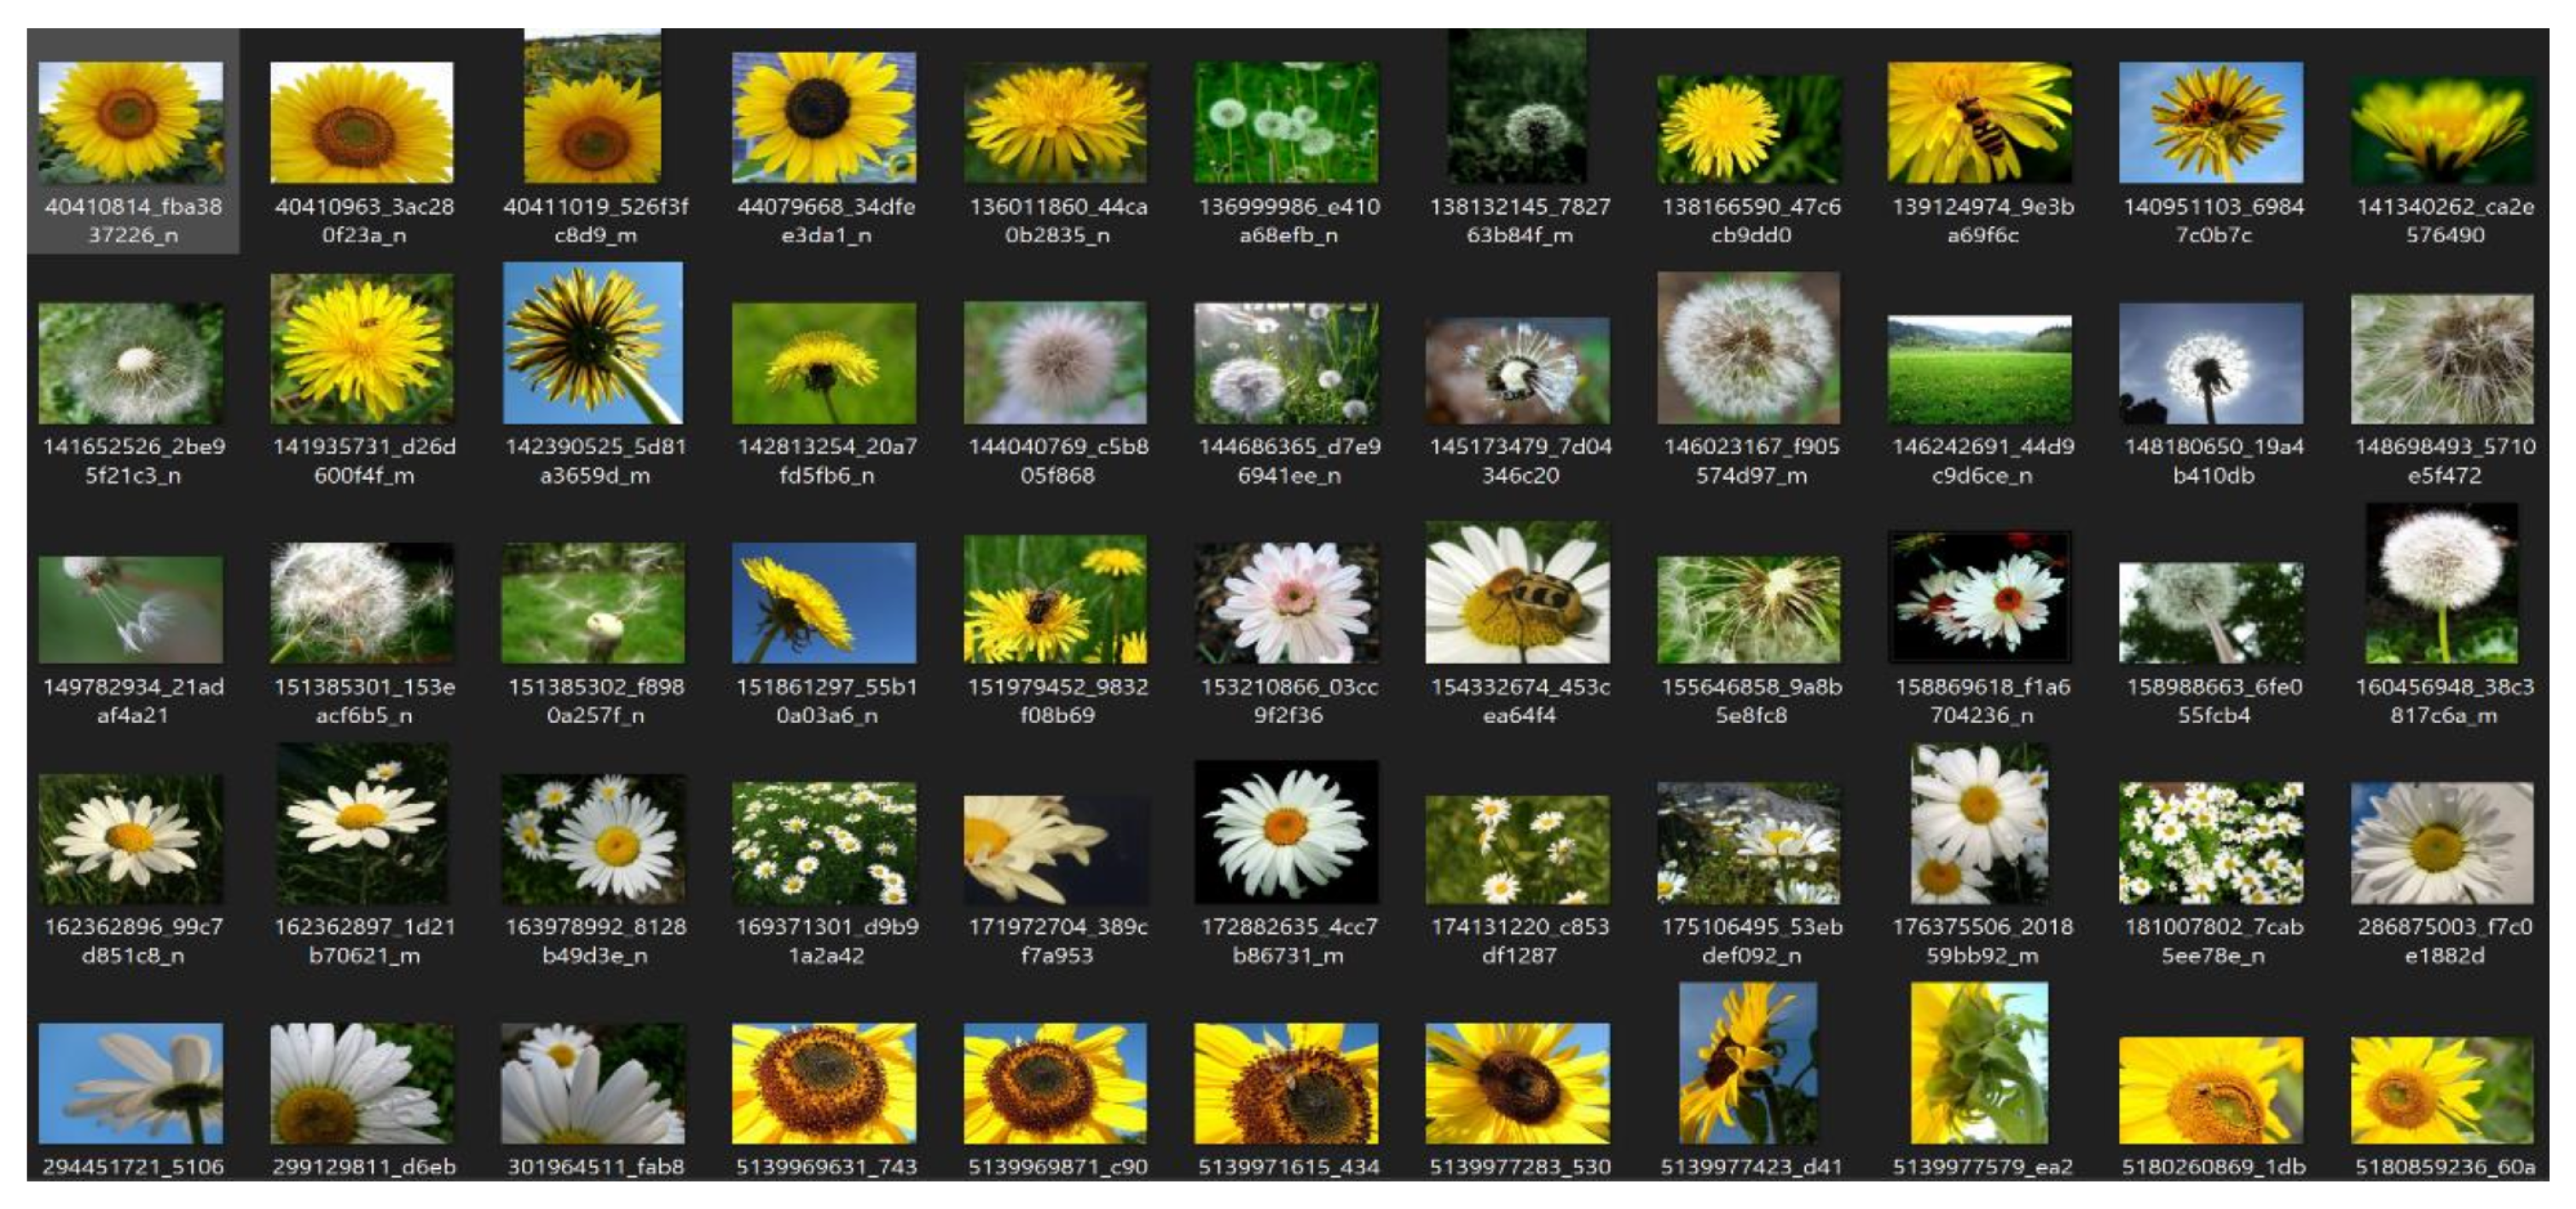
- Data Sources: The training set consists entirely of a proprietary database created for this research. All images were captured directly within the experimental laboratory environment to ensure strict environmental consistency and accurate representation of the micro-UAV’s operational conditions.
- Dataset Size: A total of 555 image samples were collected and utilized for the model’s training and evaluation phases.
- Class Distribution: The 555 samples were distributed across two primary categories: the ‘flower’ class (featuring sunflowers) and the ‘non-flower’ class.
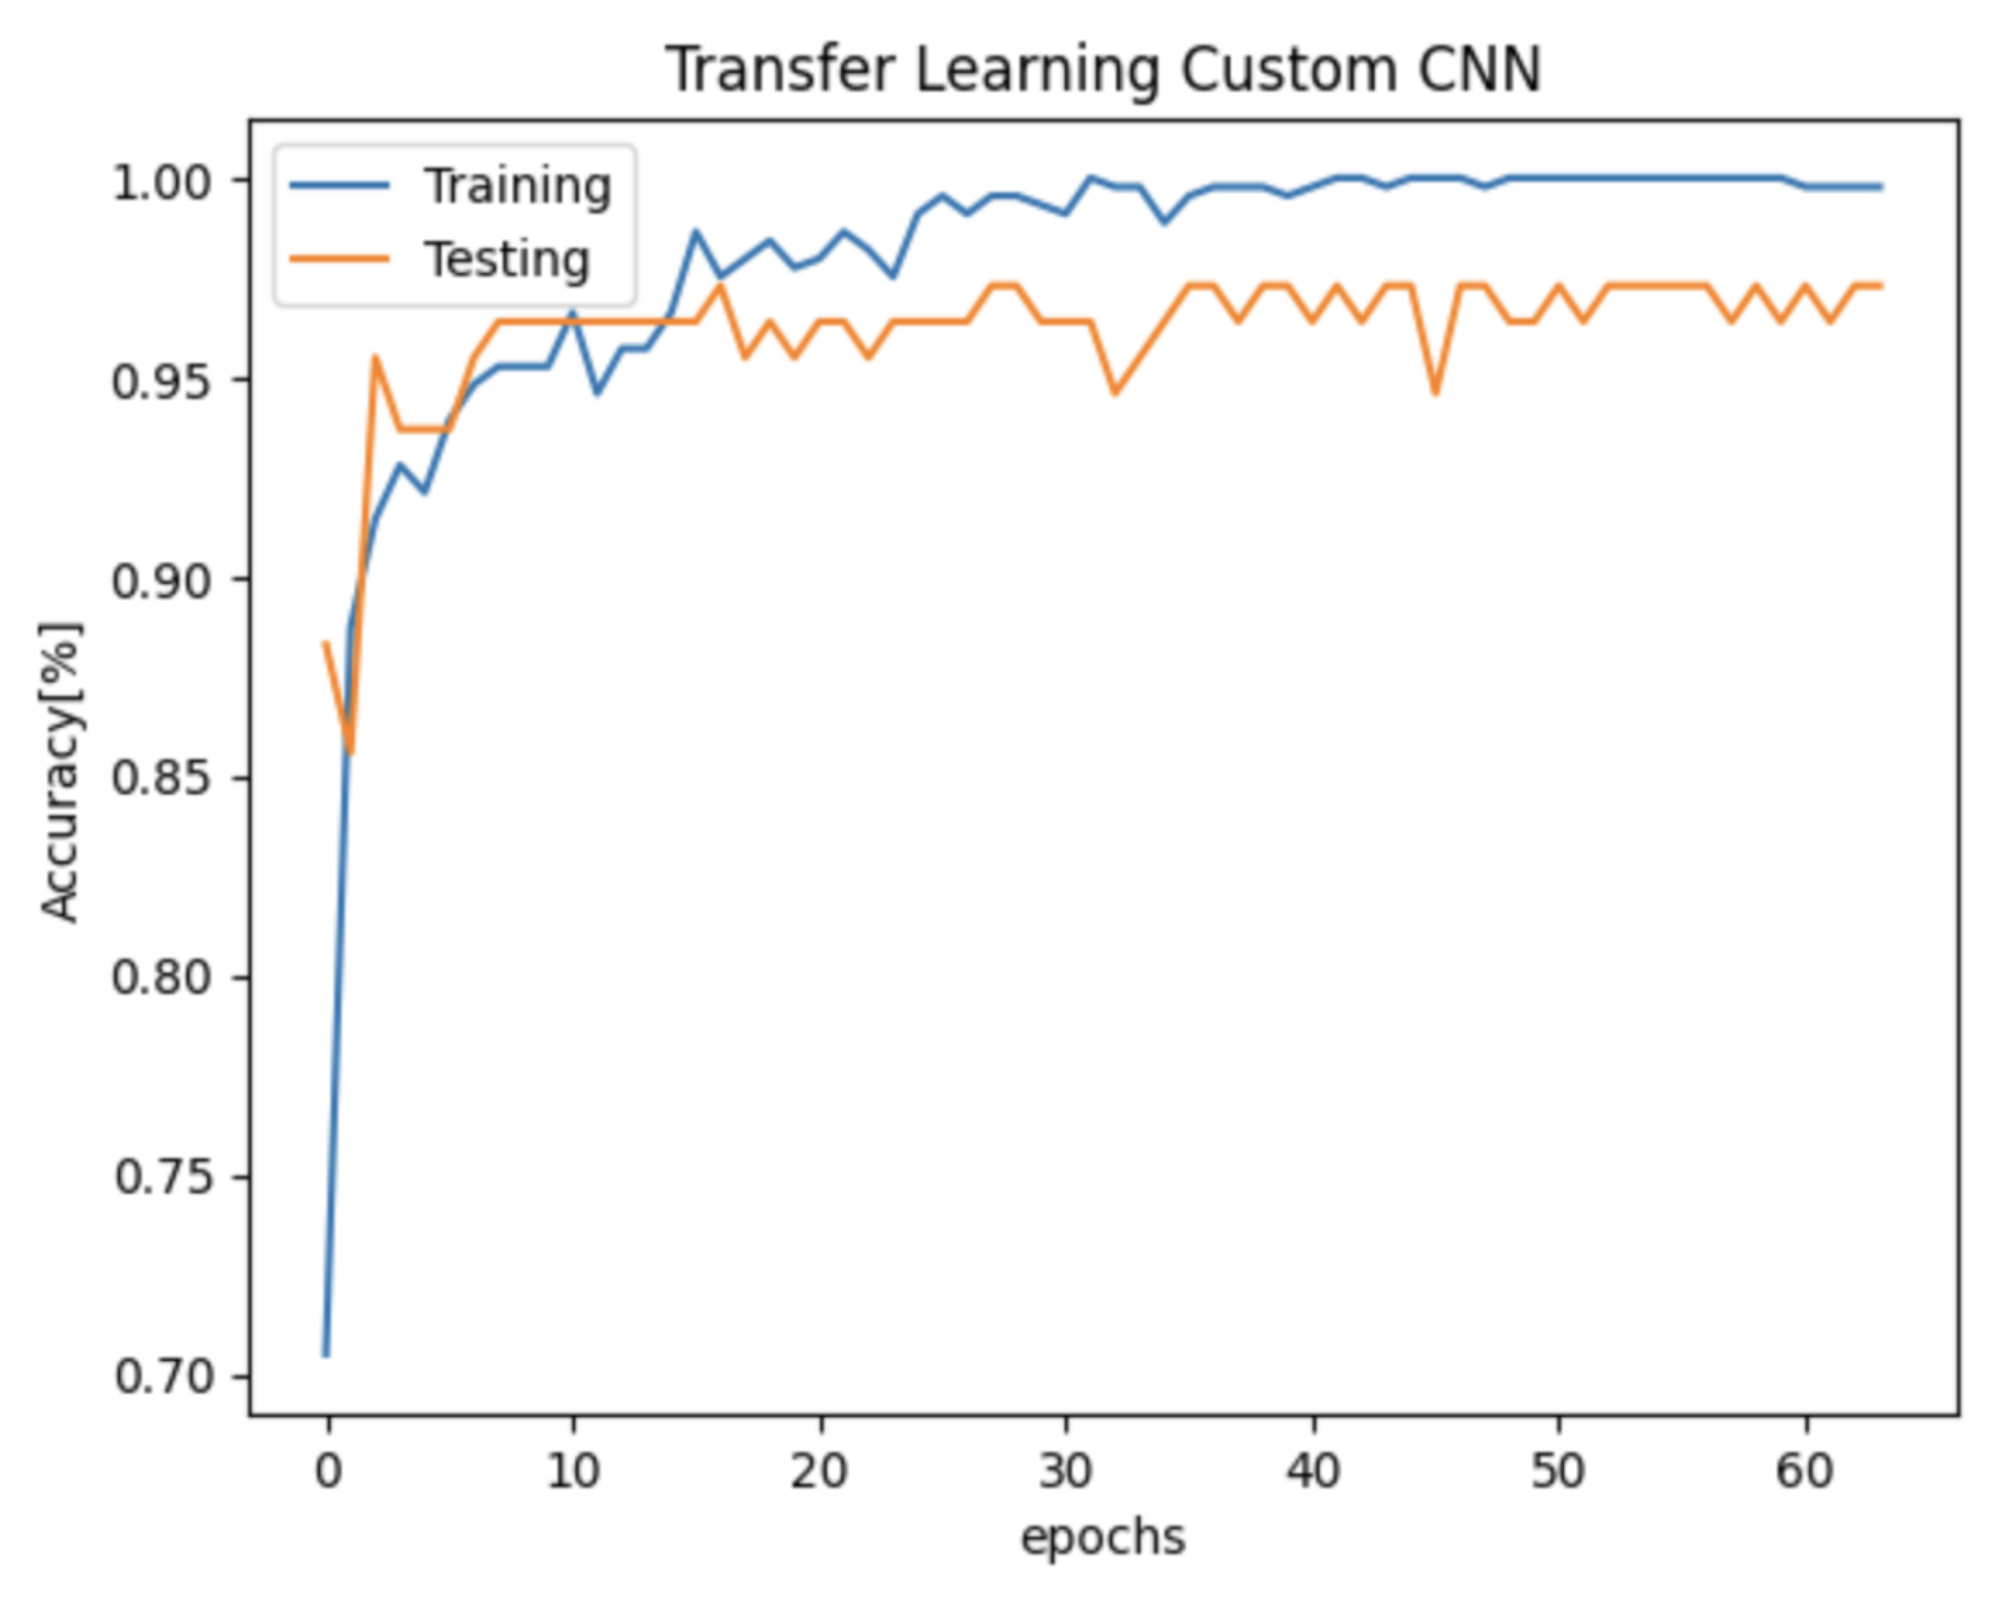
- Data Partitioning: The dataset was partitioned into two subsets: 80% for training (444 images) to train the custom sequential model and update its internal weights over the 64 epochs, and the remaining 20% (111 images) was reserved for validation and testing to tune hyperparameters and evaluate final performance.
- Preprocessing: All images were resized to a standard pixel resolution and normalized to match the input requirements of the custom sequential CNN framework.
- Data Augmentation: In this foundational phase of the research, no data augmentation techniques were applied. The custom sequential model was trained exclusively on the original raw dataset to establish a baseline for detection performance in the controlled laboratory environment.
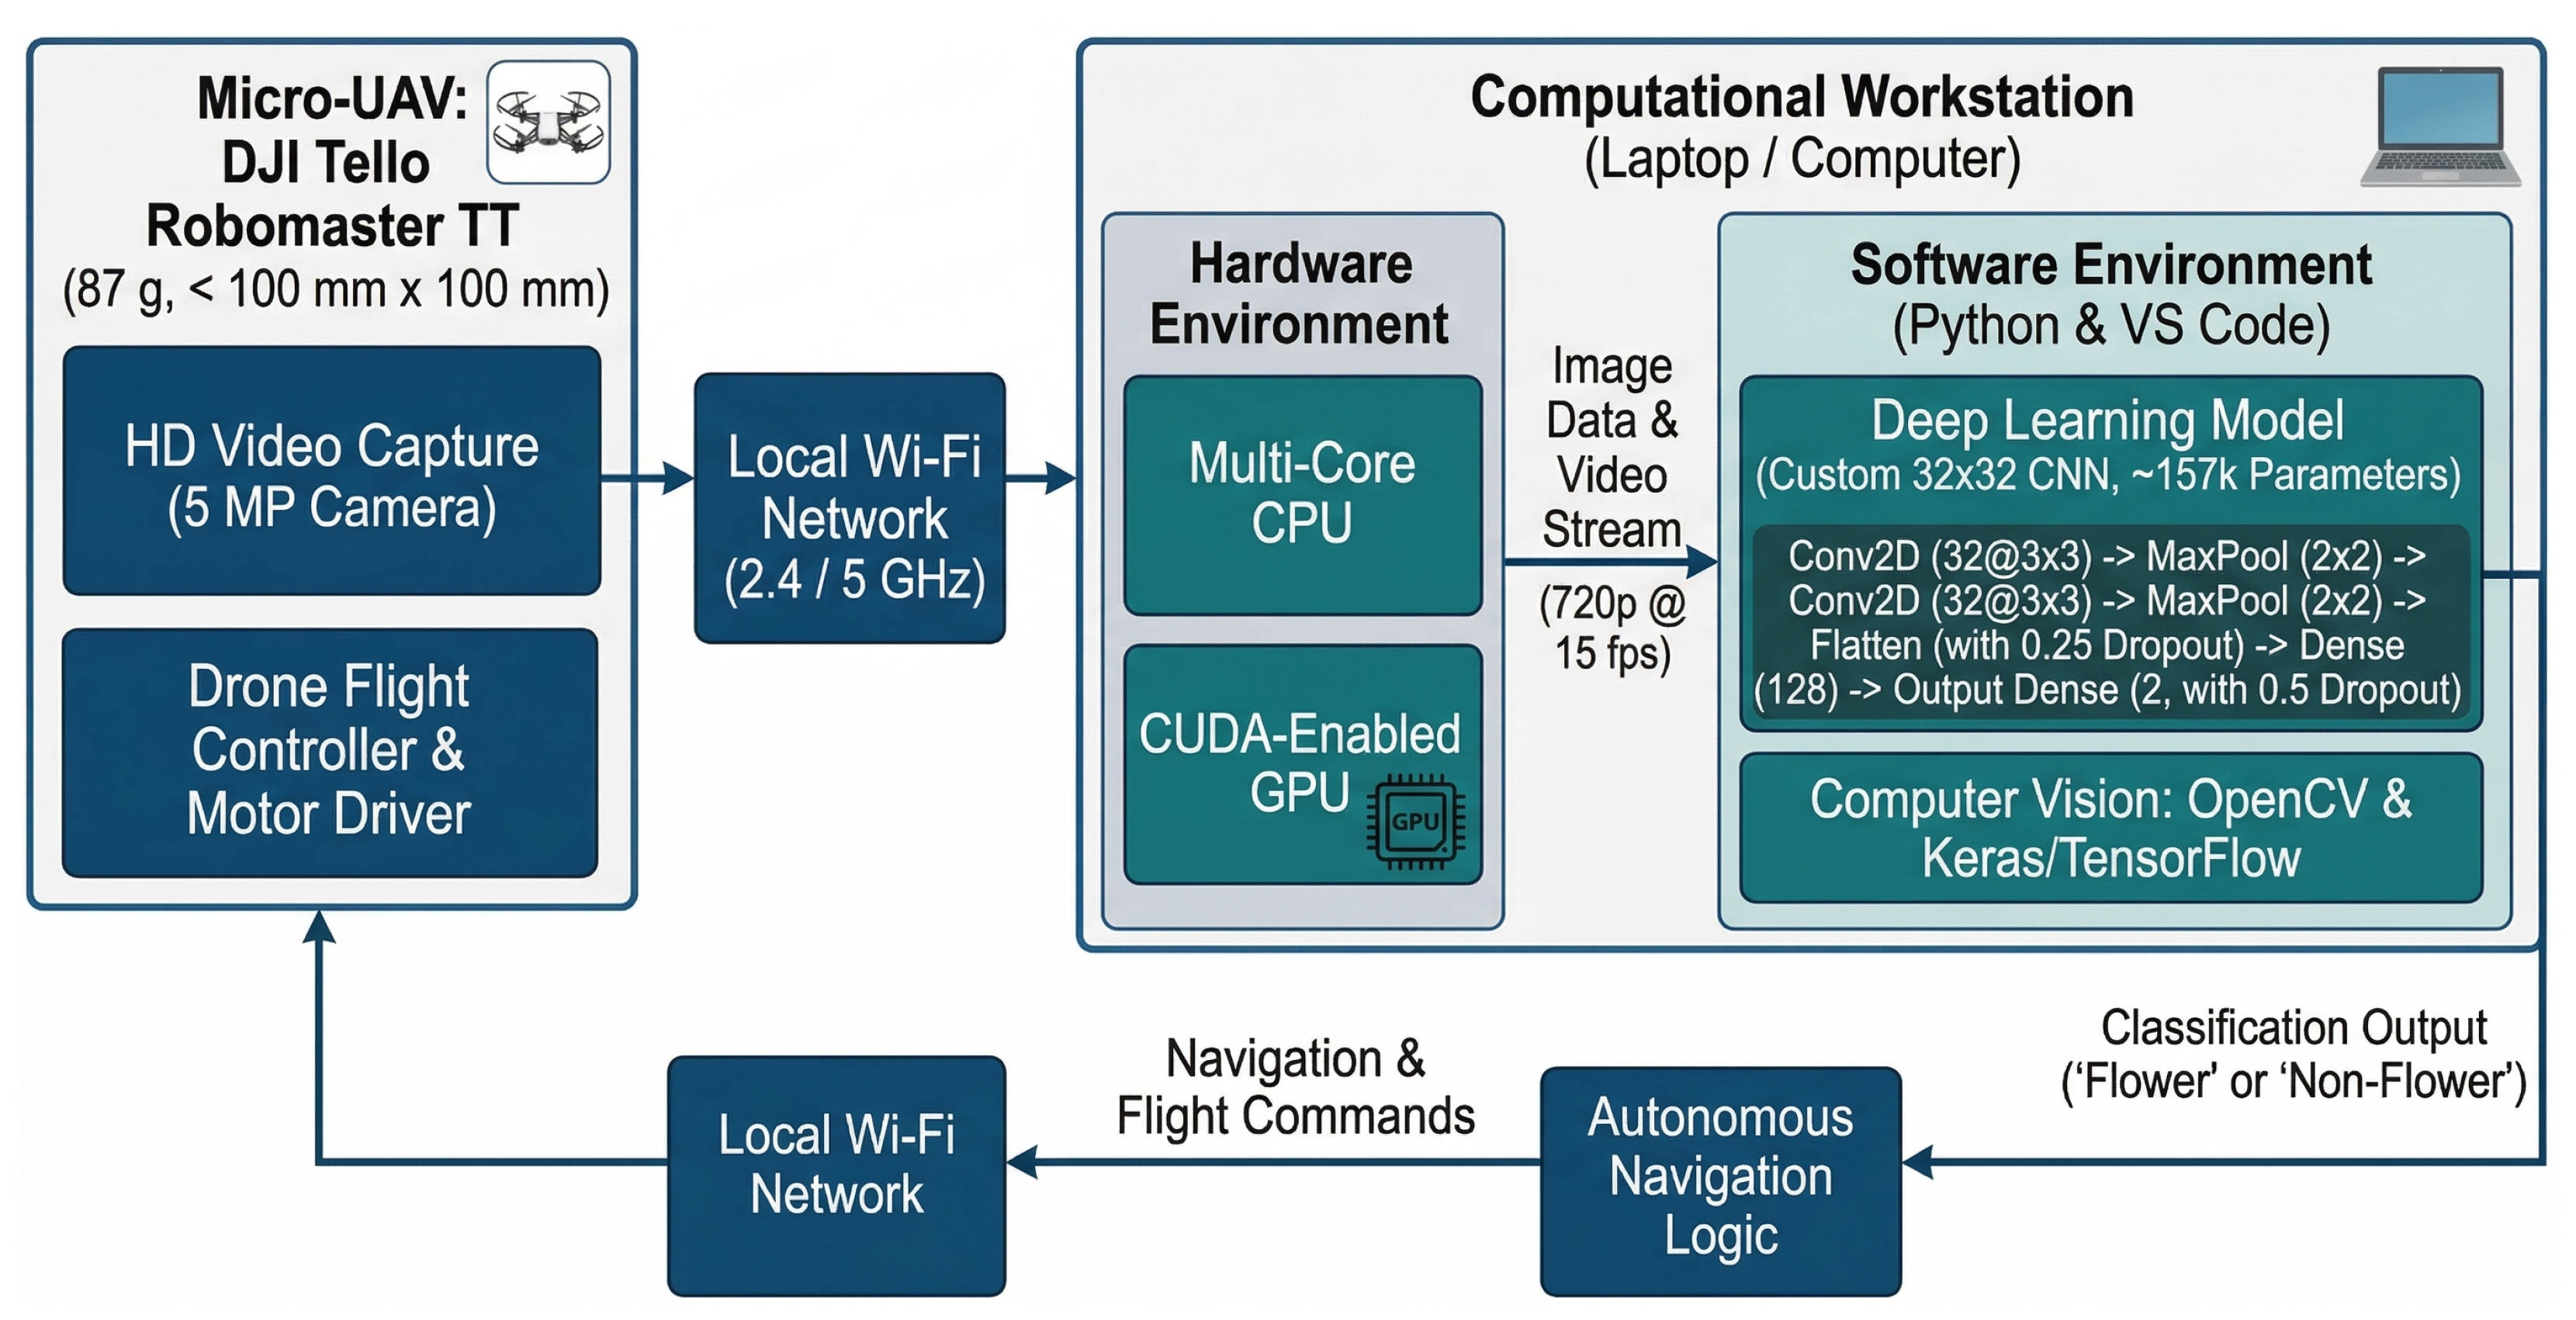
- A Conv2D input layer with 32 filters and a 3 × 3 kernel size.
- A MaxPooling2D layer with a 2 × 2 pool size.
- A second Conv2D layer with 32 filters and a 3 × 3 kernel size.
- A second MaxPooling2D layer with a 2 × 2 pool size.
- A Flatten layer, preceded by a 0.25 Dropout layer to mitigate overfitting.
- A fully connected Dense layer with 128 units.
- A final output Dense layer with 2 units, preceded by a 0.5 Dropout layer.
- Hardware Environment:
- –
- The database loading, network training, and image processing tasks were executed on a local laptop computer, which was subsequently connected to the DJI Tello Robomaster TT drone for real-time inference. Because the OpenCV processes are computationally intensive, the system leveraged a Graphics Processing Unit (GPU) equipped with Compute Unified Device Architecture (CUDA) capabilities. This provided the essential computational power and dedicated CUDA cores required to accelerate the model training and maintain real-time object detection performance.
- Software Environment:
- –
- Programming Language & IDE: Python version 3 served as the primary programming language for developing the machine learning algorithms, processing images, and training the CNN. Visual Studio Code (VS Code) version 1.70 was utilized as the integrated development environment (IDE) to write, debug, and execute the training routines.
- –
- Computer Vision & Deep Learning Libraries: OpenCV, an open-source computer vision library, was employed for intensive image and video processing, feature extraction, and object recognition tasks. The deep learning implementation and actual model training were conducted utilizing the Keras and TensorFlow frameworks, supported by NumPy for numerical data manipulation.
3.2. Micro-UAV Specification
3.3. Integration of AI Detection Capability on the Micro-UAV
4. Results and Discussion
5. Conclusions
Author Contributions
Funding
Data Availability Statement
Acknowledgments
Conflicts of Interest
Abbreviations
| UAV | Unmanned Aerial Vehicle |
| CNN | Convolution Neural Network |
| SDG | Sustainable Development Goal |
| IoT | Internet of Things |
| AI | Artificial Intelligence |
| VTOL | Vertical Takeoff and Landing |
| GPS | Global Positioning Systems |
| VSLAM | Visual Simultaneous Localization and Mapping |
| GPU | Graphics Processing Unit |
| CUDA | Compute Unified Device Architecture |
| IDE | Integrated Development Environment |
References
- Steiner, G.; Geissler, B.; Schernhammer, E.S. Hunger and Obesity as Symptoms of Non-Sustainable Food Systems and Malnutrition. Appl. Sci. 2019, 9, 1062. [Google Scholar] [CrossRef] [Scilit]
- Islam, S. Agriculture, food security, and sustainability: A review. Explor. Foods Foodomics 2025, 3, 101082. [Google Scholar] [CrossRef] [Scilit]
- Paudel, D.; Neupane, R.C.; Sigdel, S.; Poudel, P.; Khanal, A.R. COVID-19 Pandemic, Climate Change, and Conflicts on Agriculture: A Trio of Challenges to Global Food Security. Sustainability 2023, 15, 8280. [Google Scholar] [CrossRef] [Scilit]
- Raza, A.; Khare, T.; Zhang, X.; Rahman, M.M.; Hussain, M.; Gill, S.S.; Chen, Z.H.; Zhou, M.; Hu, Z.; Varshney, R.K. Novel Strategies for Designing Climate-Smart Crops to Ensure Sustainable Agriculture and Future Food Security. J. Sustain. Agric. Environ. 2025, 4, e70048. [Google Scholar] [CrossRef] [Scilit]
- Gamage, A.; Gangahagedara, R.; Subasinghe, S.; Gamage, J.; Guruge, C.; Senaratne, S.; Randika, T.; Rathnayake, C.; Hameed, Z.; Madhujith, T.; et al. Advancing sustainability: The impact of emerging technologies in agriculture. Curr. Plant Biol. 2024, 40, 100420. [Google Scholar] [CrossRef] [Scilit]
- Nazarov, A.; Kulikova, E.; Molokova, E. Economic security through technological advancements in agriculture: A pathway to sustainable agro-industrial growth. BIO Web Conf. 2024, 121, 02012. [Google Scholar] [CrossRef] [Scilit]
- AlZubi, A.A.; Galyna, K. Artificial Intelligence and Internet of Things for Sustainable Farming and Smart Agriculture. IEEE Access 2023, 11, 78686–78692. [Google Scholar] [CrossRef] [Scilit]
- Patel, A.; Shukla, C.; Trivedi, A.; Balasaheb, K.S.; Sinha, M.K. Smart Farming: Utilization of Robotics, Drones, Remote Sensing, GIS, AI, and IoT Tools in Agricultural Operations and Water Management. In Integrated Land and Water Resource Management for Sustainable Agriculture Volume 1; Jadhav, D.A., Khaple, S., Wable, P.S., Chendake, A.D., Eds.; Springer Nature: Singapore, 2025; pp. 127–151. [Google Scholar]
- Aarif K. O., M.; Alam, A.; Hotak, Y. Smart Sensor Technologies Shaping the Future of Precision Agriculture: Recent Advances and Future Outlooks. J. Sens. 2025, 2025, 2460098. [Google Scholar] [CrossRef] [Scilit]
- Moradi, S.; Bokani, A.; Hassan, J. UAV-based smart agriculture: A review of UAV sensing and applications. In Proceedings of the 2022 32nd International Telecommunication Networks and Applications Conference (ITNAC), Wellington, New Zealand, 30 November–2 December 2022; IEEE: New York, NY, USA, 2022; pp. 181–184. [Google Scholar]
- Lu, K.; Zhang, X.; Zhai, T.; Zhou, M. Adaptive sharding for UAV networks: A deep reinforcement learning approach to blockchain optimization. Sensors 2024, 24, 7279. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Caruso, A.; Chessa, S.; Lopez, J.C.; Escolar, S.; Barba, J. Collection of Data With Drones in Precision Agriculture: Analytical Model and LoRa Case Study. IEEE Internet Things J. 2021, 8, 16692–16704. [Google Scholar] [CrossRef] [Scilit]
- Yin, J.; Lan, Y.; Long, Y.; Wu, B.; Jiang, L.; Zhan, H.; Zhu, J.; Xu, H.; Deng, H.; Chen, G. An Intelligent Field Monitoring System Based on Enhanced YOLO-RMD Architecture for Real-Time Rice Pest Detection and Management. Agriculture 2025, 15, 798. [Google Scholar] [CrossRef] [Scilit]
- Wang, T.; Zhao, Y.; Li Pang, L.L.; Cheng, Q. Evaluation method and design of greenhouse pear pollination drones based on grounded theory and integrated theory. PLoS ONE 2024, 19, e0311297. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Miyoshi, K.; Hiraguri, T.; Shimizu, H.; Hattori, K.; Kimura, T.; Okubo, S.; Endo, K.; Shimada, T.; Shibasaki, A.; Takemura, Y. Development of Pear Pollination System Using Autonomous Drones. AgriEngineering 2025, 7, 68. [Google Scholar] [CrossRef] [Scilit]
- Bersani, C.; Ouammi, A.; Sacile, R.; Zero, E. Model Predictive Control of Smart Greenhouses as the Path towards Near Zero Energy Consumption. Energies 2020, 13, 3647. [Google Scholar] [CrossRef] [Scilit]
- Hati, A.J.; Singh, R.R. Smart Indoor Farms: Leveraging Technological Advancements to Power a Sustainable Agricultural Revolution. AgriEngineering 2021, 3, 728–767. [Google Scholar] [CrossRef] [Scilit]
- Singh, S.; Singh, P.; Kumar, A.; Baheliya, A.K.; Patel, K.K. Promoting Environmental Sustainability Through Vertical Farming: A Review. J. Adv. Biol. Biotechnol. 2024, 27, 210–219. [Google Scholar] [CrossRef] [Scilit]
- Hiraguri, T.; Shimizu, H.; Kimura, T.; Matsuda, T.; Maruta, K.; Takemura, Y.; Ohya, T.; Takanashi, T. Autonomous Drone-Based Pollination System Using AI Classifier to Replace Bees for Greenhouse Tomato Cultivation. IEEE Access 2023, 11, 99352–99364. [Google Scholar] [CrossRef] [Scilit]
- V.J, R.; Inamdar, M.N. Impact of Autonomous Drone Pollination in Date Palms. Int. J. Innov. Res. Sci. Stud. 2022, 5, 297–305. [Google Scholar] [CrossRef] [Scilit]
- Sadeh, A.; Shmida, A.; Keasar, T. The Carpenter Bee Xylocopa pubescens as an Agricultural Pollinator in Greenhouses. Apidologie 2007, 38, 508–517. [Google Scholar] [CrossRef] [Scilit]
- Slaa, E.J.; Chaves, L.A.S.; Malagodi-Braga, K.S.; Hofstede, F.E. Stingless bees in applied pollination: Practice and perspectives. Apidologie 2006, 37, 293–315. [Google Scholar] [CrossRef] [Scilit]
- Strader, J.; Nguyen, J.; Tatsch, C.; Du, Y.; Lassak, K.; Buzzo, B.; Watson, R.; Cerbone, H.; Ohi, N.; Yang, C.; et al. Flower Interaction Subsystem for a Precision Pollination Robot. In Proceedings of the 2019 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Macau, China, 3–8 November 2019; IEEE: New York, NY, USA, 2019; pp. 5534–5541. [Google Scholar] [CrossRef] [Scilit]
- Ohi, N.; Lassak, K.; Watson, R.; Strader, J.; Du, Y.; Yang, C.; Hedrick, G.; Nguyen, J.; Harper, S.; Reynolds, D.; et al. Design of an Autonomous Precision Pollination Robot. In Proceedings of the 2018 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Madrid, Spain, 1–5 October 2018; IEEE: New York, NY, USA, 2018; pp. 7711–7718. [Google Scholar] [CrossRef] [Scilit]
- Lochan, K.; Khan, A.; Elsayed, I.; Suthar, B.; Seneviratne, L.; Hussain, I. Advancements in Precision Spraying of Agricultural Robots: A Comprehensive Review. IEEE Access 2024, 12, 129447–129483. [Google Scholar] [CrossRef] [Scilit]
- Karim, M.J. Autonomous Pollination System for Tomato Plants in Greenhouses: Integrating Deep Learning and Robotic Hardware Manipulation on Edge Device. In Proceedings of the 2024 International Conference on Innovations in Science, Engineering and Technology (ICISET), Chittagong, Bangladesh, 26–27 October 2024; IEEE: New York, NY, USA, 2024; pp. 1–6. [Google Scholar] [CrossRef] [Scilit]
- Agrawal, J.; Arafat, M.Y. Transforming Farming: A Review of AI-Powered UAV Technologies in Precision Agriculture. Drones 2024, 8, 664. [Google Scholar] [CrossRef] [Scilit]
- Broussard, M.A.; Coates, M.; Martinsen, P. Artificial Pollination Technologies: A Review. Agronomy 2023, 13, 1351. [Google Scholar] [CrossRef] [Scilit]
- Bell, J. Robots for Kiwifruit Harvesting and Pollination. arXiv 2025, arXiv:2507.15484. [Google Scholar] [CrossRef] [Scilit]
- Wu, P.; Lei, X.; Zeng, J.; Qi, Y.; Yuan, Q.; Huang, W.; Ma, Z.; Shen, Q.; Lyu, X. Research progress in mechanized and intelligentized pollination technologies for fruit and vegetable crops. Int. J. Agric. Biol. Eng. 2024, 17, 11–21. [Google Scholar] [CrossRef] [Scilit]
- Manzoor, S.H.; Kabir, M.H.; Zhang, Z. UAV-based apple flowers pollination system. In Towards Unmanned Apple Orchard Production Cycle: Recent New Technologies; Springer: Berlin/Heidelberg, Germany, 2023; pp. 211–236. [Google Scholar]
- Yablokova, A.; Kovalev, D.; Kovalev, I.; Podoplelova, V.; Astanakulov, K. Environmental safety problems of swarm use of UAVs in precision agriculture. In E3S Web of Conferences; EDP Sciences: Les Ulis, France, 2024; Volume 471, p. 04018. [Google Scholar]
- Montilla-Pacheco, A.d.J.; Pacheco-Gil, H.A.; Pastrán-Calles, F.R.; Rodríguez-Pincay, I.R. Pollination with drones: A successful response to the decline of entomophiles pollinators? Sci. Agropecu. 2021, 12, 509–516. [Google Scholar] [CrossRef] [Scilit]
- Francis, C.D.; Kleist, N.J.; Ortega, C.P.; Cruz, A. Noise pollution alters ecological services: Enhanced pollination and disrupted seed dispersal. Proc. R. Soc. B Biol. Sci. 2012, 279, 2727–2735. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Stehr, N.J. Drones: The Newest Technology for Precision Agriculture. Nat. Sci. Educ. 2015, 44, 89–91. [Google Scholar] [CrossRef] [Scilit]
- García-Munguía, A.; Guerra-Ávila, P.L.; García-Munguía, A.M.; Islas-Ojeda, E.; Vázquez-Martínez, O.; Flores-Sánchez, J.L.; García-Munguía, O. A Review of Drone Technology and Operation Processes in Agricultural Crop Spraying. Drones 2024, 8, 674. [Google Scholar] [CrossRef] [Scilit]
- Akbar, J.U.M.; Kamarulzaman, S.F.; Muzahid, A.J.M.; Rahman, M.A.; Uddin, M. A comprehensive review on deep learning assisted computer vision techniques for smart greenhouse agriculture. IEEE Access 2024, 12, 4485–4522. [Google Scholar] [CrossRef] [Scilit]
- Apriyanti, D.H.; Spreeuwers, L.J.; Lucas, P.J. Explainable automated wild-orchid identification combining deep neural networks and Bayesian networks. Eng. Appl. Artif. Intell. 2025, 161, 111961. [Google Scholar] [CrossRef] [Scilit]
- Arafat, M.Y.; Alam, M.M.; Moh, S. Vision-Based Navigation Techniques for Unmanned Aerial Vehicles: Review and Challenges. Drones 2023, 7, 89. [Google Scholar] [CrossRef] [Scilit]
- Choutri, K.; Shaiba, H.; Meshoul, S.; Chegrani, A.; Yahiaoui, M.; Lagha, M. Vision-Based UAV Detection and Localization to Indoor Positioning System. Sensors 2024, 24, 4121. [Google Scholar] [CrossRef] [Scilit]
- Liu, Y.; Tan, Y. A Review of Visual SLAM Systems Based on Multi-Sensor Fusion. In Proceedings of the 2024 9th International Conference on Intelligent Informatics and Biomedical Sciences (ICIIBMS), Okinawa, Japan, 21–23 November 2024; IEEE: New York, NY, USA, 2024; Volume 9, pp. 304–310. [Google Scholar]
- Ruotsalainen, L.; Sokolova, N.; Morrison, A.; Rantanen, J.; Makela, M. Improving Computer Vision-Based Perception for Collaborative Indoor Navigation. IEEE Sens. J. 2022, 22, 4816–4826. [Google Scholar] [CrossRef] [Scilit]
- Gupta, A.; Fernando, X. Simultaneous localization and mapping (slam) and data fusion in unmanned aerial vehicles: Recent advances and challenges. Drones 2022, 6, 85. [Google Scholar] [CrossRef] [Scilit]
- Bach, S.H.; Yi, S.Y.; Khoi, P.B. Application of QR Code for Localization and Navigation of Indoor Mobile Robot. IEEE Access 2023, 11, 28384–28390. [Google Scholar] [CrossRef] [Scilit]
- Li, M.; Zhao, M.; Mao, H.; Gao, H. Development and Experimentation of a Real-Time Greenhouse Positioning System Based on IUKF-UWB. Agriculture 2024, 14, 1479. [Google Scholar] [CrossRef] [Scilit]
- Rahman, M.F.F.; Zhang, Y.; Chen, L.; Fan, S. A Comparative Study on Application of Unmanned Aerial Vehicle Systems in Agriculture. Agriculture 2021, 11, 22. [Google Scholar] [CrossRef] [Scilit]
- Suherman, S.; Pinem, M.; Putra, R.A. Ultrasonic Sensor Assessment for Obstacle Avoidance in Quadcopter-based Drone System. In Proceedings of the 2020 3rd International Conference on Mechanical, Electronics, Computer, and Industrial Technology (MECnIT), Medan, Indonesia, 25–27 June 2020; Institute of Electrical Electronics Engineers: New York, NY, USA, 2020; pp. 50–53. [Google Scholar] [CrossRef] [Scilit]
- Cheng, B.; He, X.; Li, X.; Zhang, N.; Song, W.; Wu, H. Research on Positioning and Navigation System of Greenhouse Mobile Robot Based on Multi-Sensor Fusion. Sensors 2024, 24, 4998. [Google Scholar] [CrossRef] [Scilit]
- Melnychenko, O.; Scislo, L.; Savenko, O.; Sachenko, A.; Radiuk, P. Intelligent integrated system for fruit detection using multi-UAV imaging and deep learning. Sensors 2024, 24, 1913. [Google Scholar] [CrossRef] [Scilit]
- Li, K.; Wei, X.; Wang, Q.; Zhang, W. Research on Strawberry Visual Recognition and 3D Localization Based on Lightweight RAFS-YOLO and RGB-D Camera. Agriculture 2025, 15, 2212. [Google Scholar] [CrossRef] [Scilit]
- Tsai, P.S.; Wu, T.F.; Wang, Y.C. Automatic Quadrotor Dispatch Missions Based on Air-Writing Gesture Recognition. Processes 2025, 13, 3984. [Google Scholar] [CrossRef] [Scilit]




| Item | Parameter | Specification |
|---|---|---|
| Drone | Take-off weight | 87 g (including propeller blades, propeller blade protector, and batteries) |
| Dimensions | mm | |
| Propeller blade | 3” | |
| Built-in functions | Infrared height determination, barometer, LED indicator, downward vision sensor, Wi-Fi, HD 750P image transmission | |
| Interface | Micro USB charging port | |
| Removable battery | 1.1 Ah/3.8 V | |
| Flight Performance | Maximum flight distance | 100 m |
| Maximum flight speed | 8 m/s | |
| Maximum flight time | 8 min | |
| Maximum flight height | 30 m | |
| Camera | Image | 5 MP |
| Field of View (FoV) | 82.6° | |
| Video | HD720P30 | |
| Format | JPG (images), MP4 (videos) | |
| Electronic image stabilization | Supported |
| Parameter | Value |
|---|---|
| Epochs | 64 |
| Batch Size | 32 |
| Optimizer | Adam |
| Learning Rate | Default (Adam) |
| Number of Detections | Webcam (Seconds) | Drone Camera (Seconds) |
|---|---|---|
| 10 | 28.01 | 11.34 |
| 20 | 44.20 | 12.73 |
| 30 | 61.65 | 13.04 |
| 40 | 90.07 | 13.43 |
| 50 | 102.55 | 14.44 |
| 60 | 129.66 | 14.86 |
| Distance (cm) | Detection (Boolean) |
|---|---|
| 15.5 | 0 |
| 30.5 | 1 |
| 60.5 | 1 |
| 91.5 | 1 |
| 116.5 | 0 |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Yusof, M.I.; Mohd Yasin, F.N.; Risangtuni, A.G.; Putra, N.K.; Samseh, S.H.; Zainal, A.; Sani, M.A.A. A CNN-Based Micro-UAV System for Real-Time Flower Detection and Target Approach. Automation 2026, 7, 69. https://doi.org/10.3390/automation7030069
Yusof MI, Mohd Yasin FN, Risangtuni AG, Putra NK, Samseh SH, Zainal A, Sani MAA. A CNN-Based Micro-UAV System for Real-Time Flower Detection and Target Approach. Automation. 2026; 7(3):69. https://doi.org/10.3390/automation7030069
Chicago/Turabian StyleYusof, Mohd Ismail, Fatin Nabilah Mohd Yasin, Ayu Gareta Risangtuni, Narendra Kurnia Putra, Siti Hafshar Samseh, Azavitra Zainal, and Mohd Aliff Afira Sani. 2026. "A CNN-Based Micro-UAV System for Real-Time Flower Detection and Target Approach" Automation 7, no. 3: 69. https://doi.org/10.3390/automation7030069
APA StyleYusof, M. I., Mohd Yasin, F. N., Risangtuni, A. G., Putra, N. K., Samseh, S. H., Zainal, A., & Sani, M. A. A. (2026). A CNN-Based Micro-UAV System for Real-Time Flower Detection and Target Approach. Automation, 7(3), 69. https://doi.org/10.3390/automation7030069