
Article

Physics-Based Simulation and Automation of a Load-Haul-Dump Operation for an Articulated Dump Truck

Oztech Inc., Columbus, OH 43202, USA
*
Author to whom correspondence should be addressed.
Vehicles 2022, 4(1), 167-181; https://doi.org/10.3390/vehicles4010011

Submission received: 30 December 2021 / Revised: 9 February 2022 / Accepted: 17 February 2022 / Published: 22 February 2022
(This article belongs to the Special Issue Driver-Vehicle Automation Collaboration)

Abstract

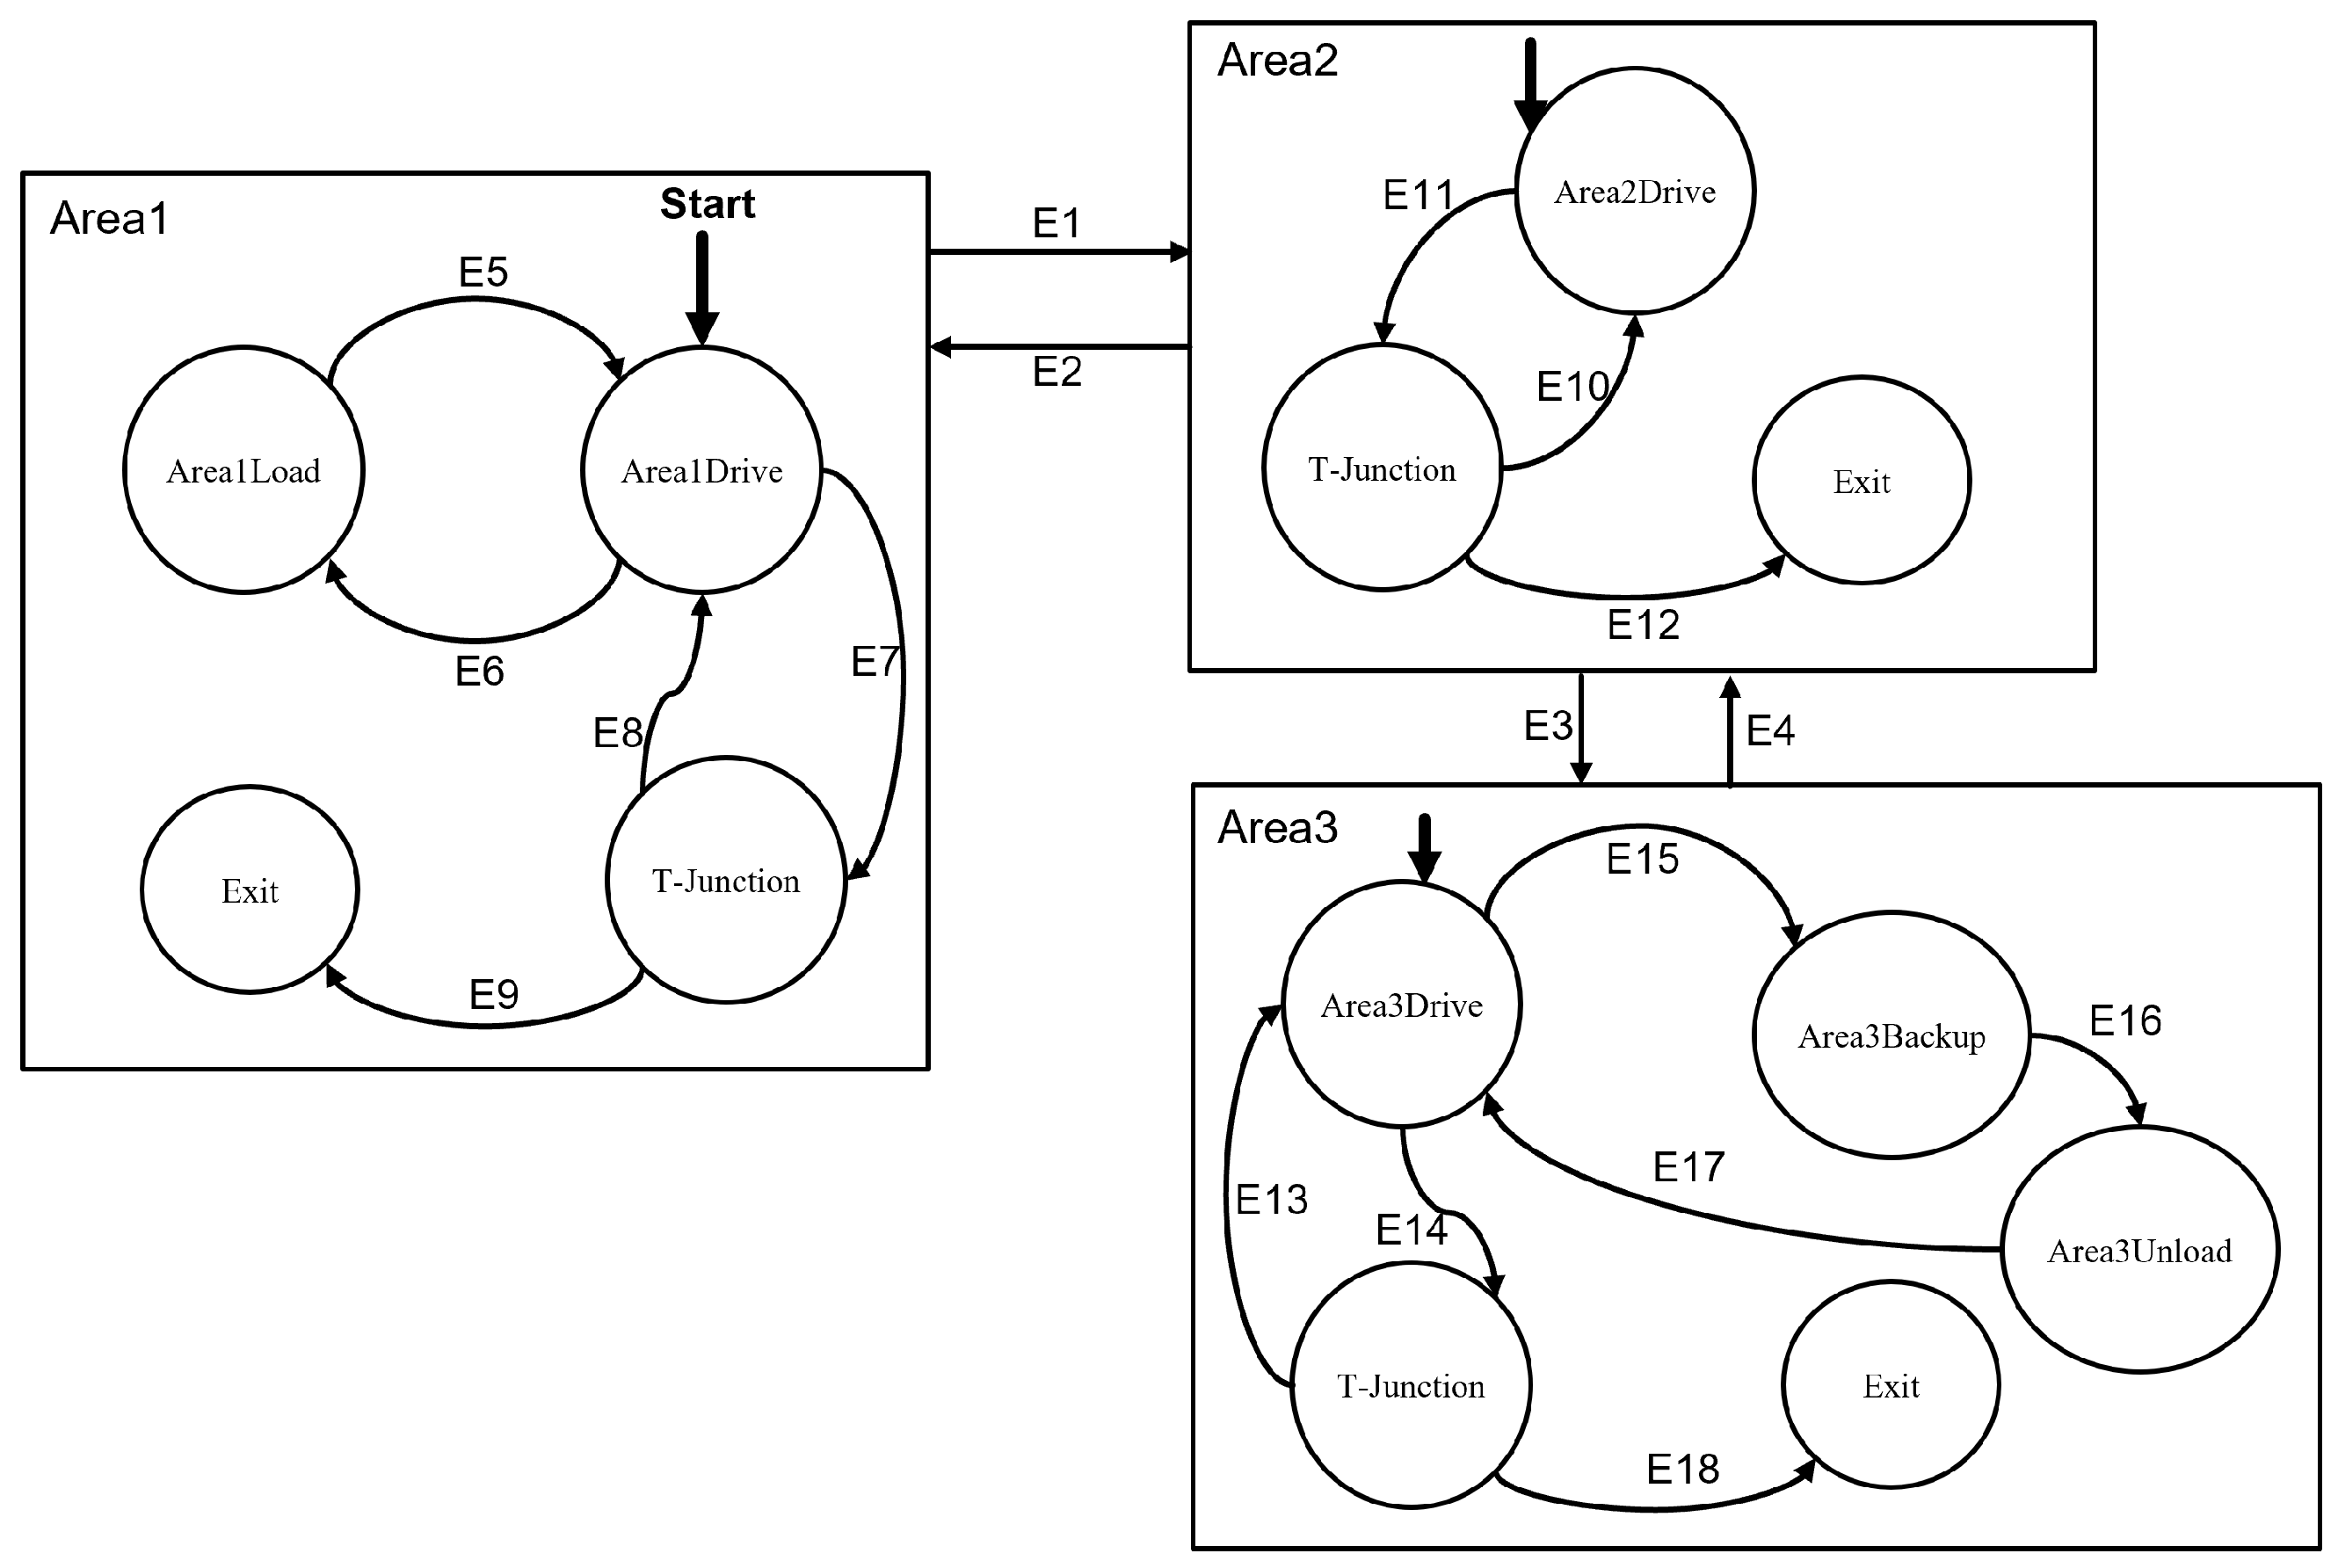
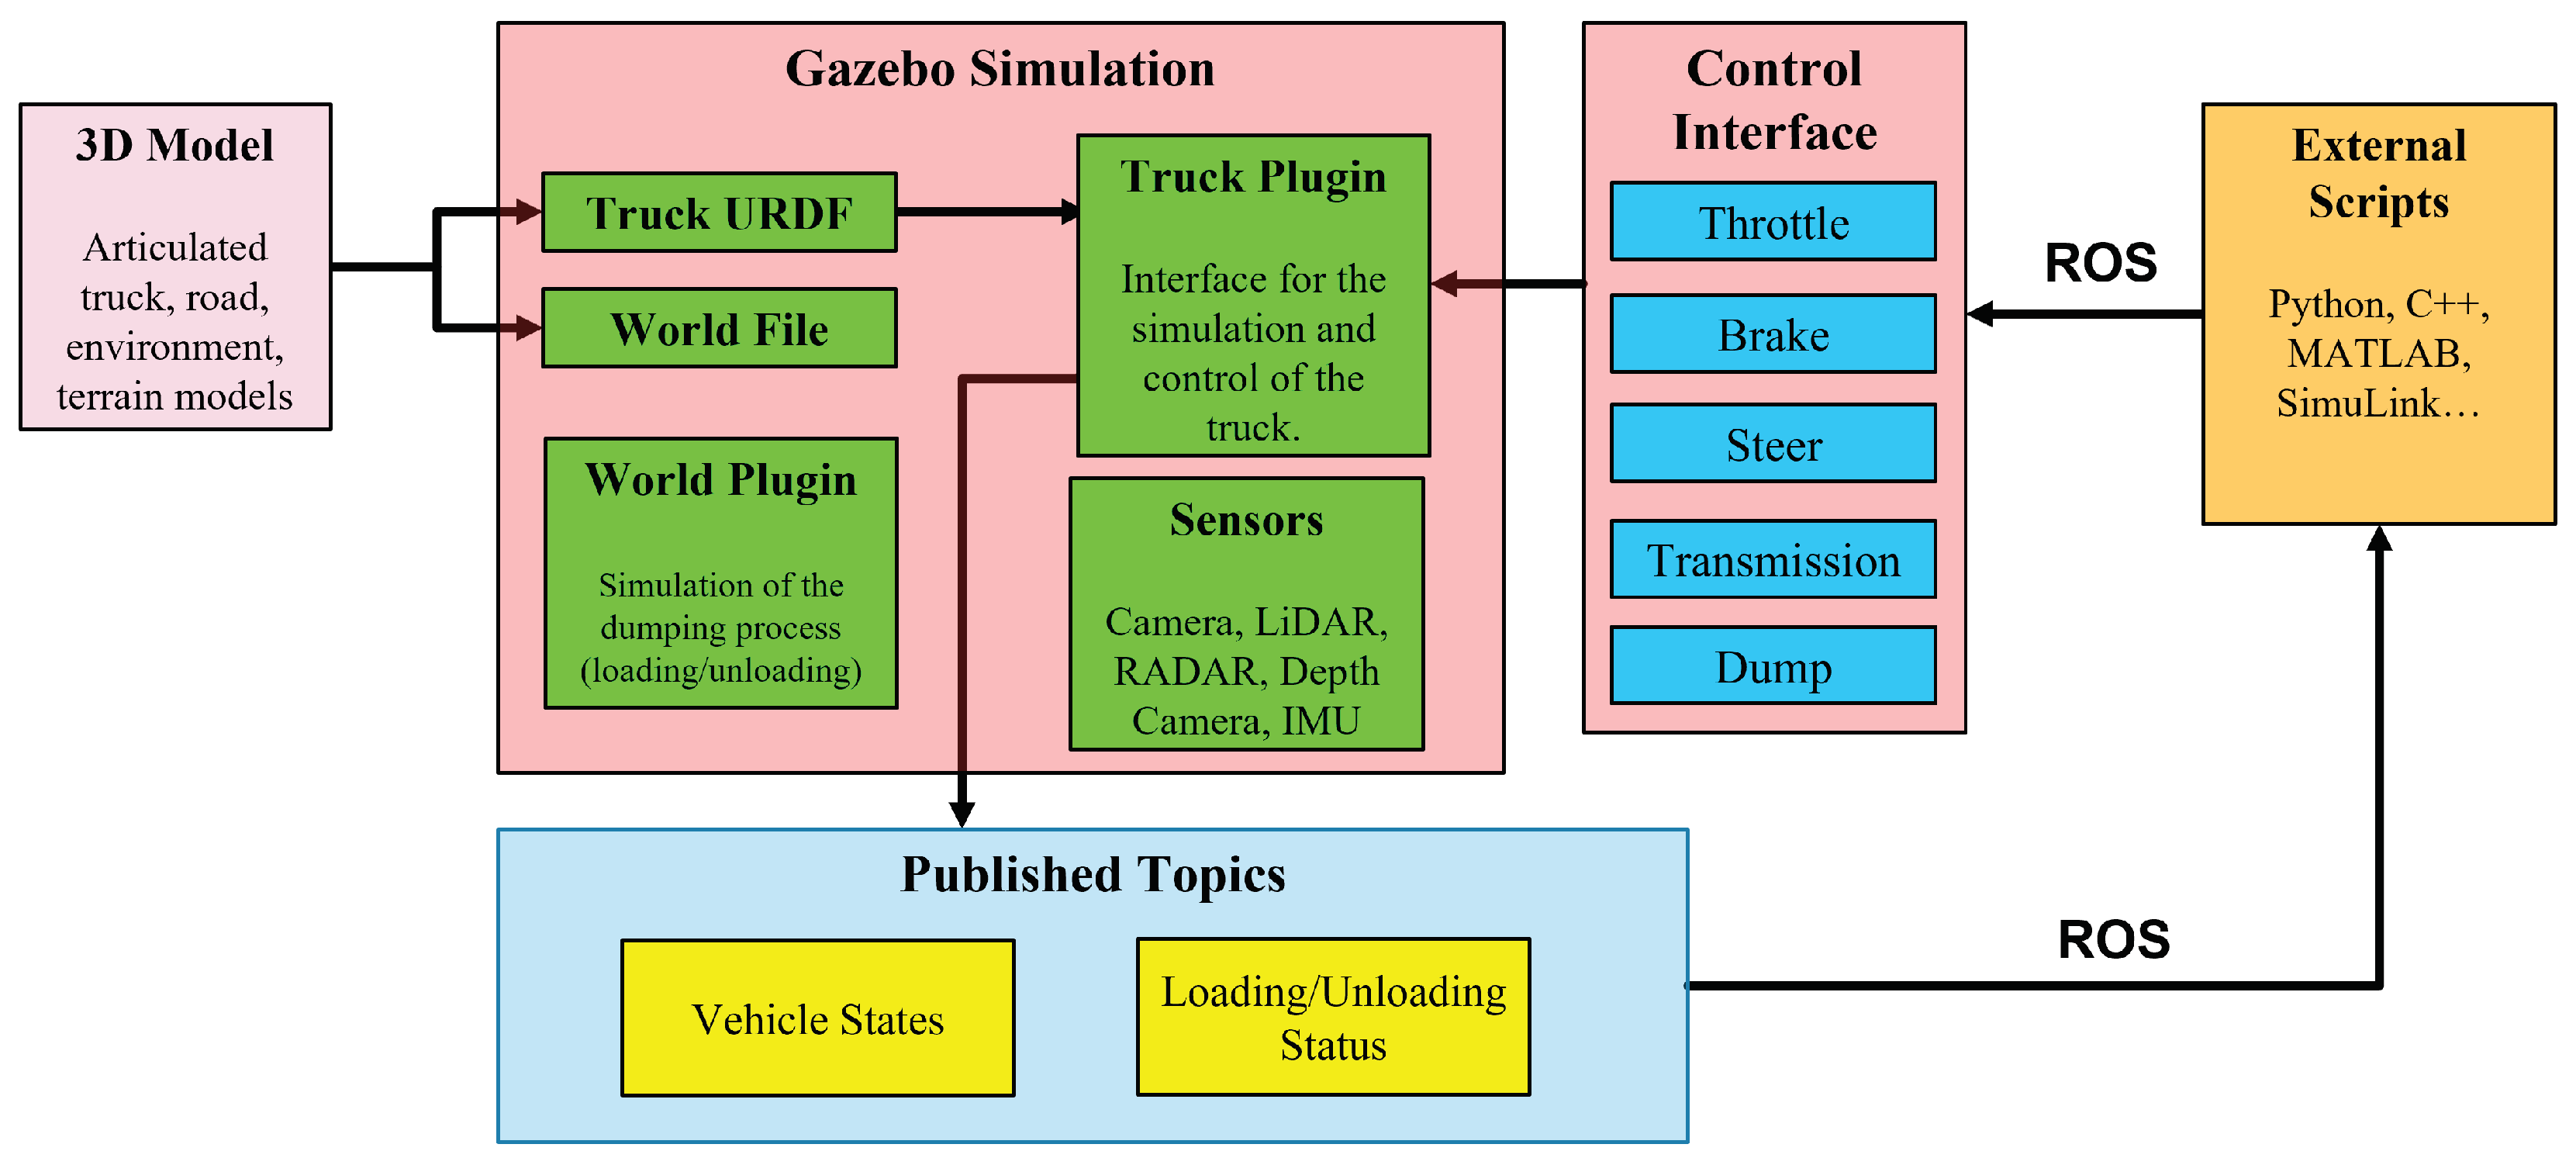
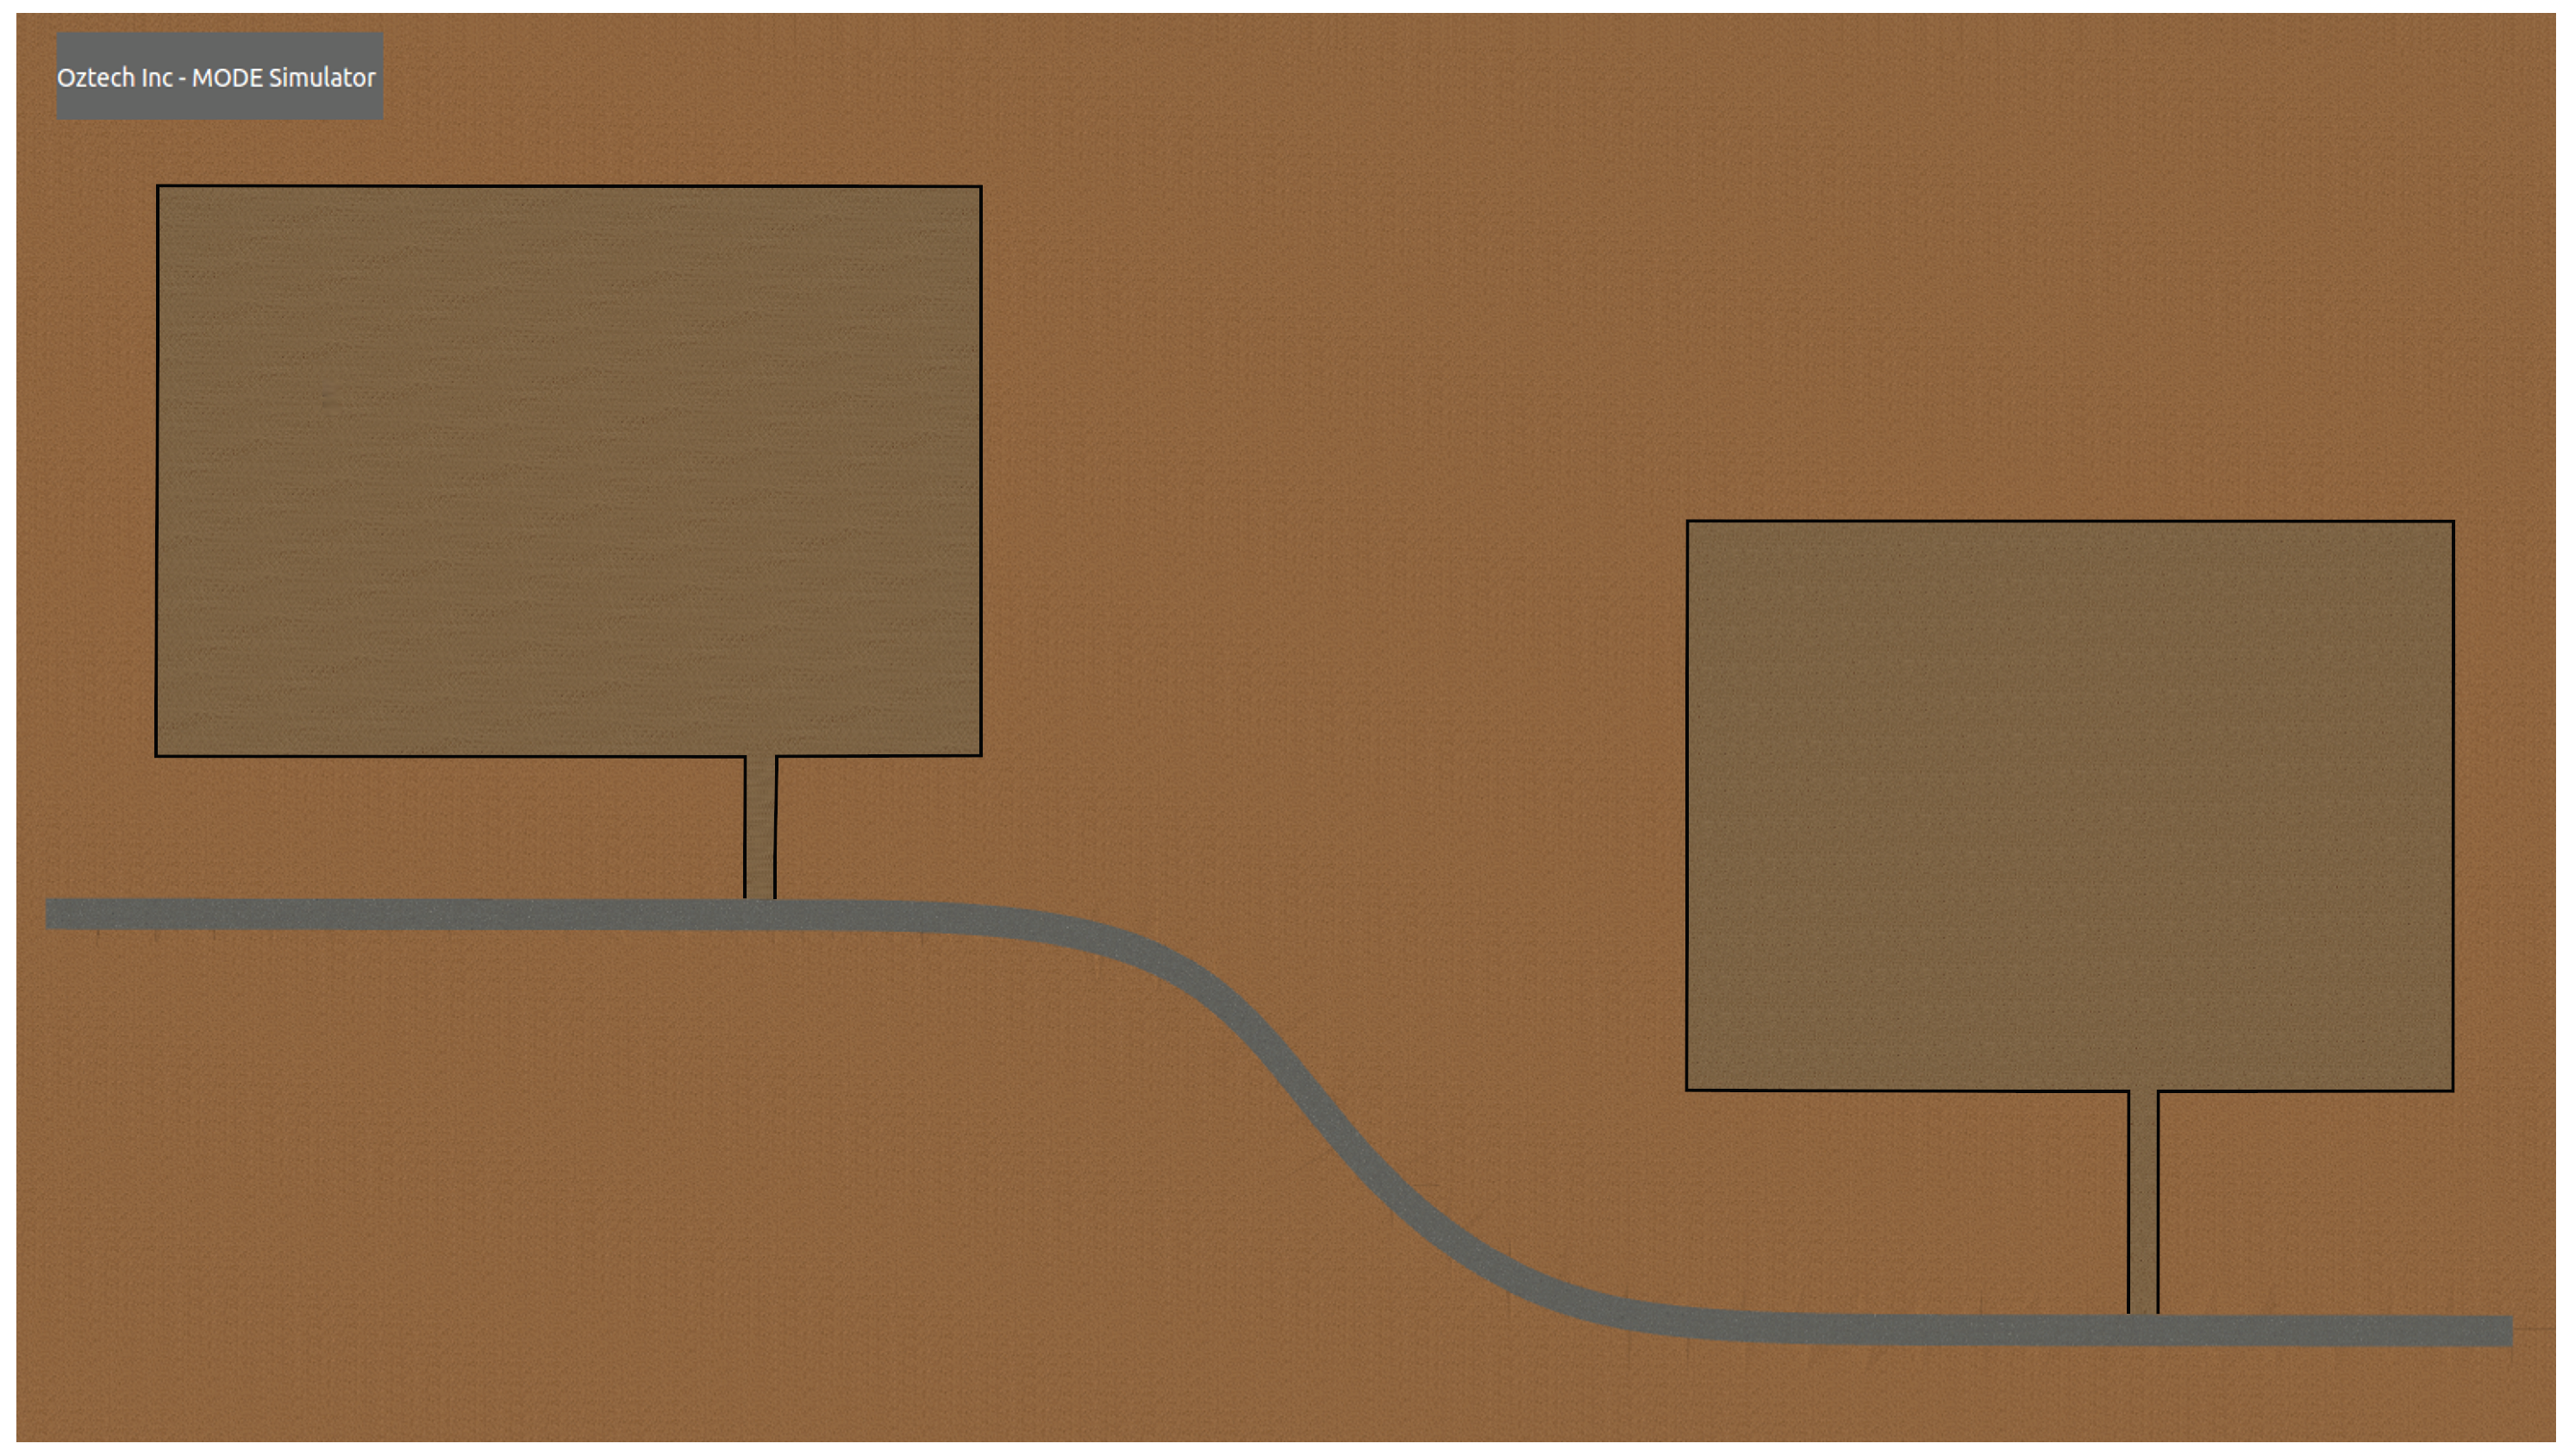
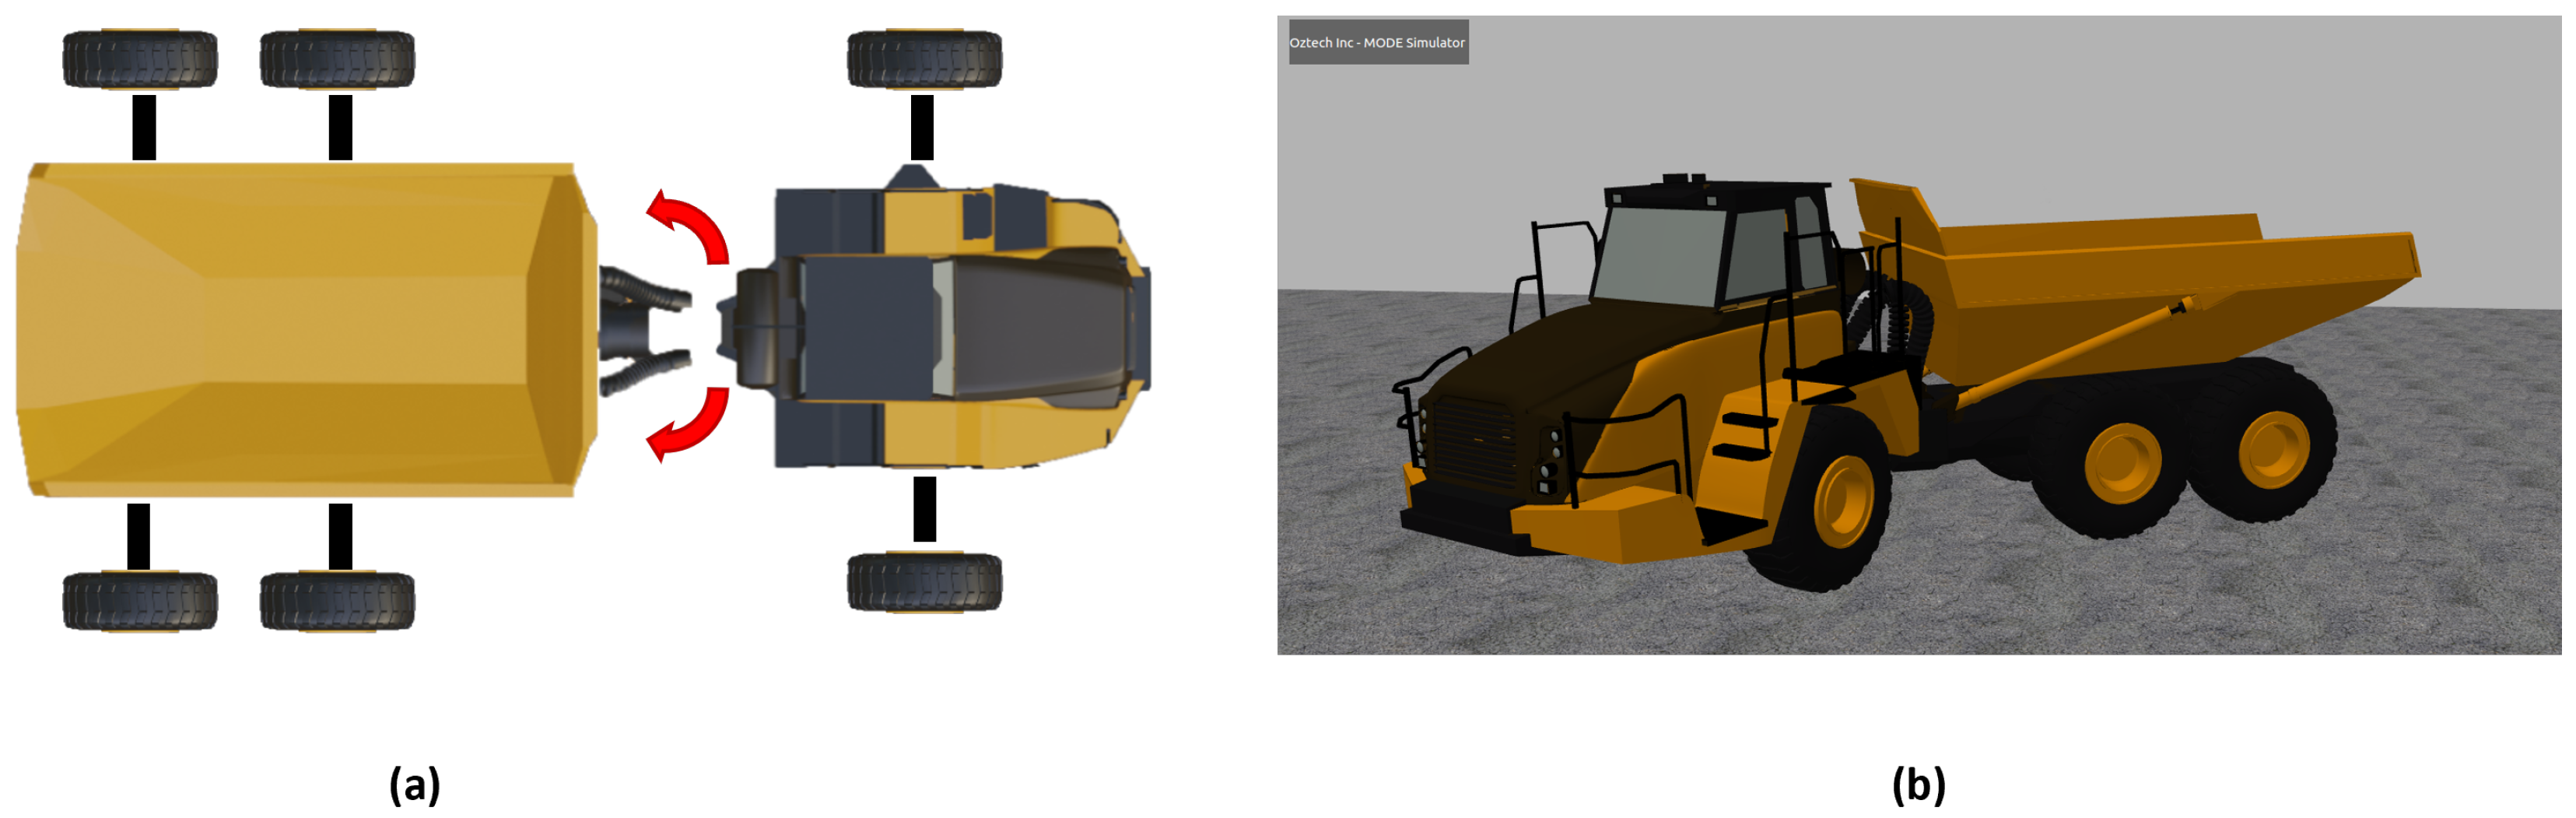
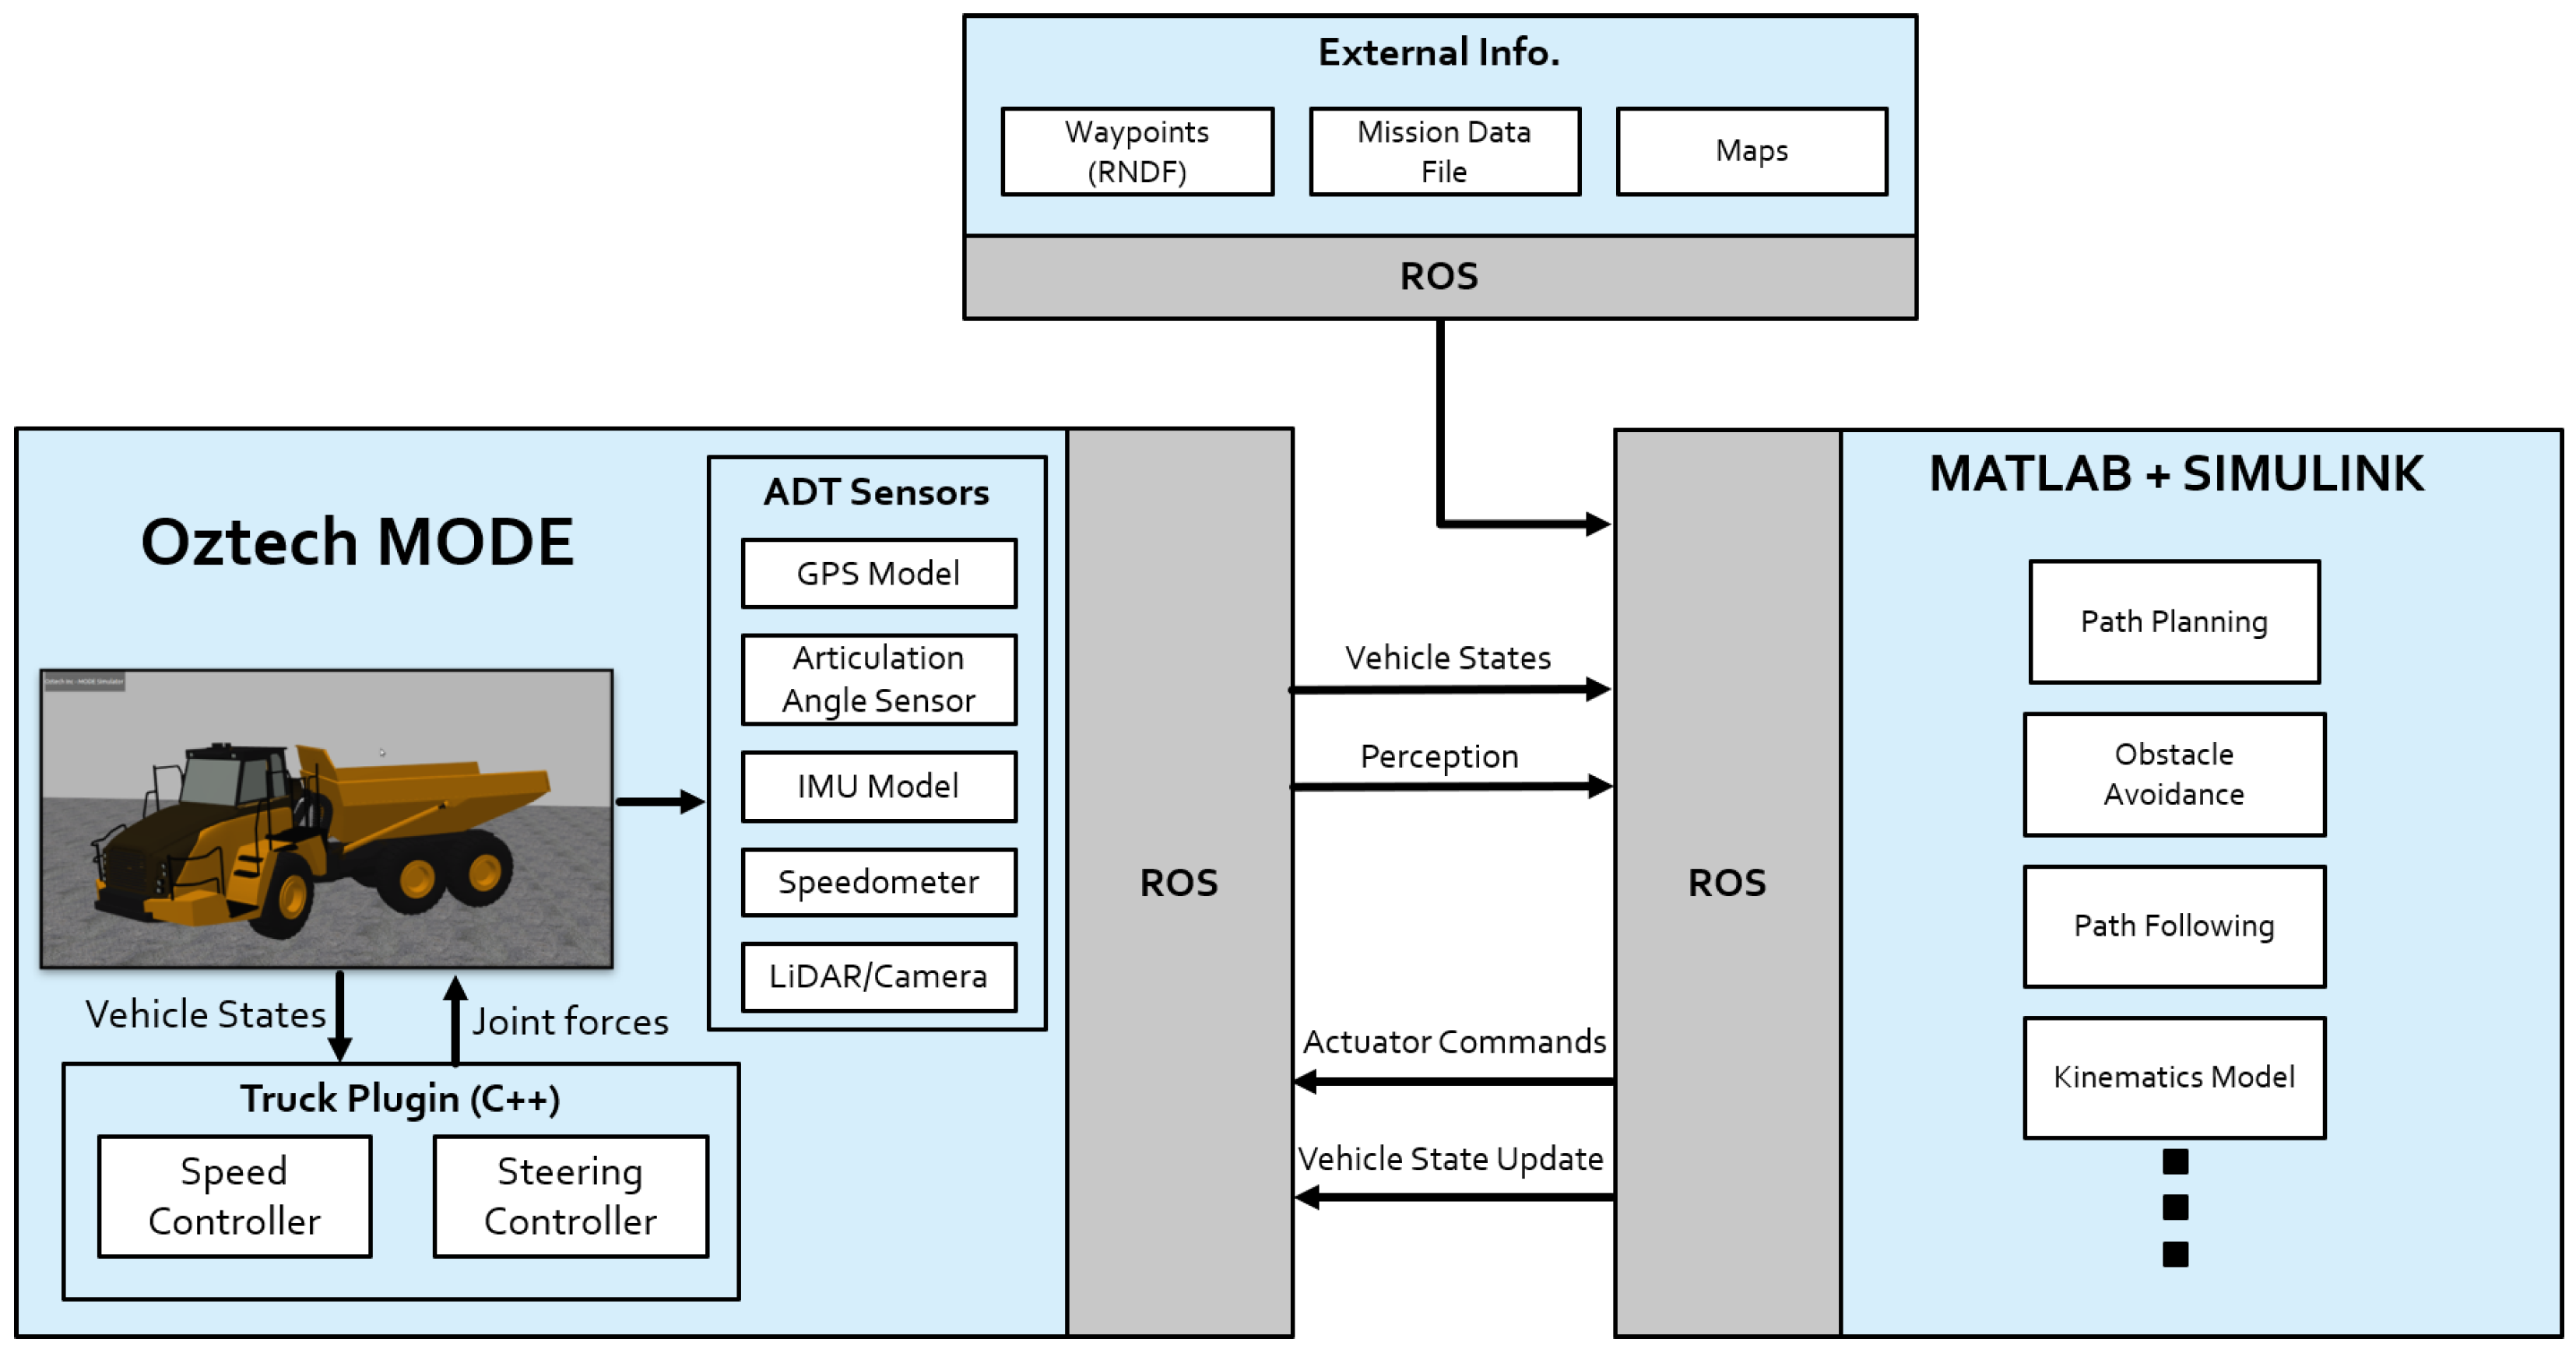
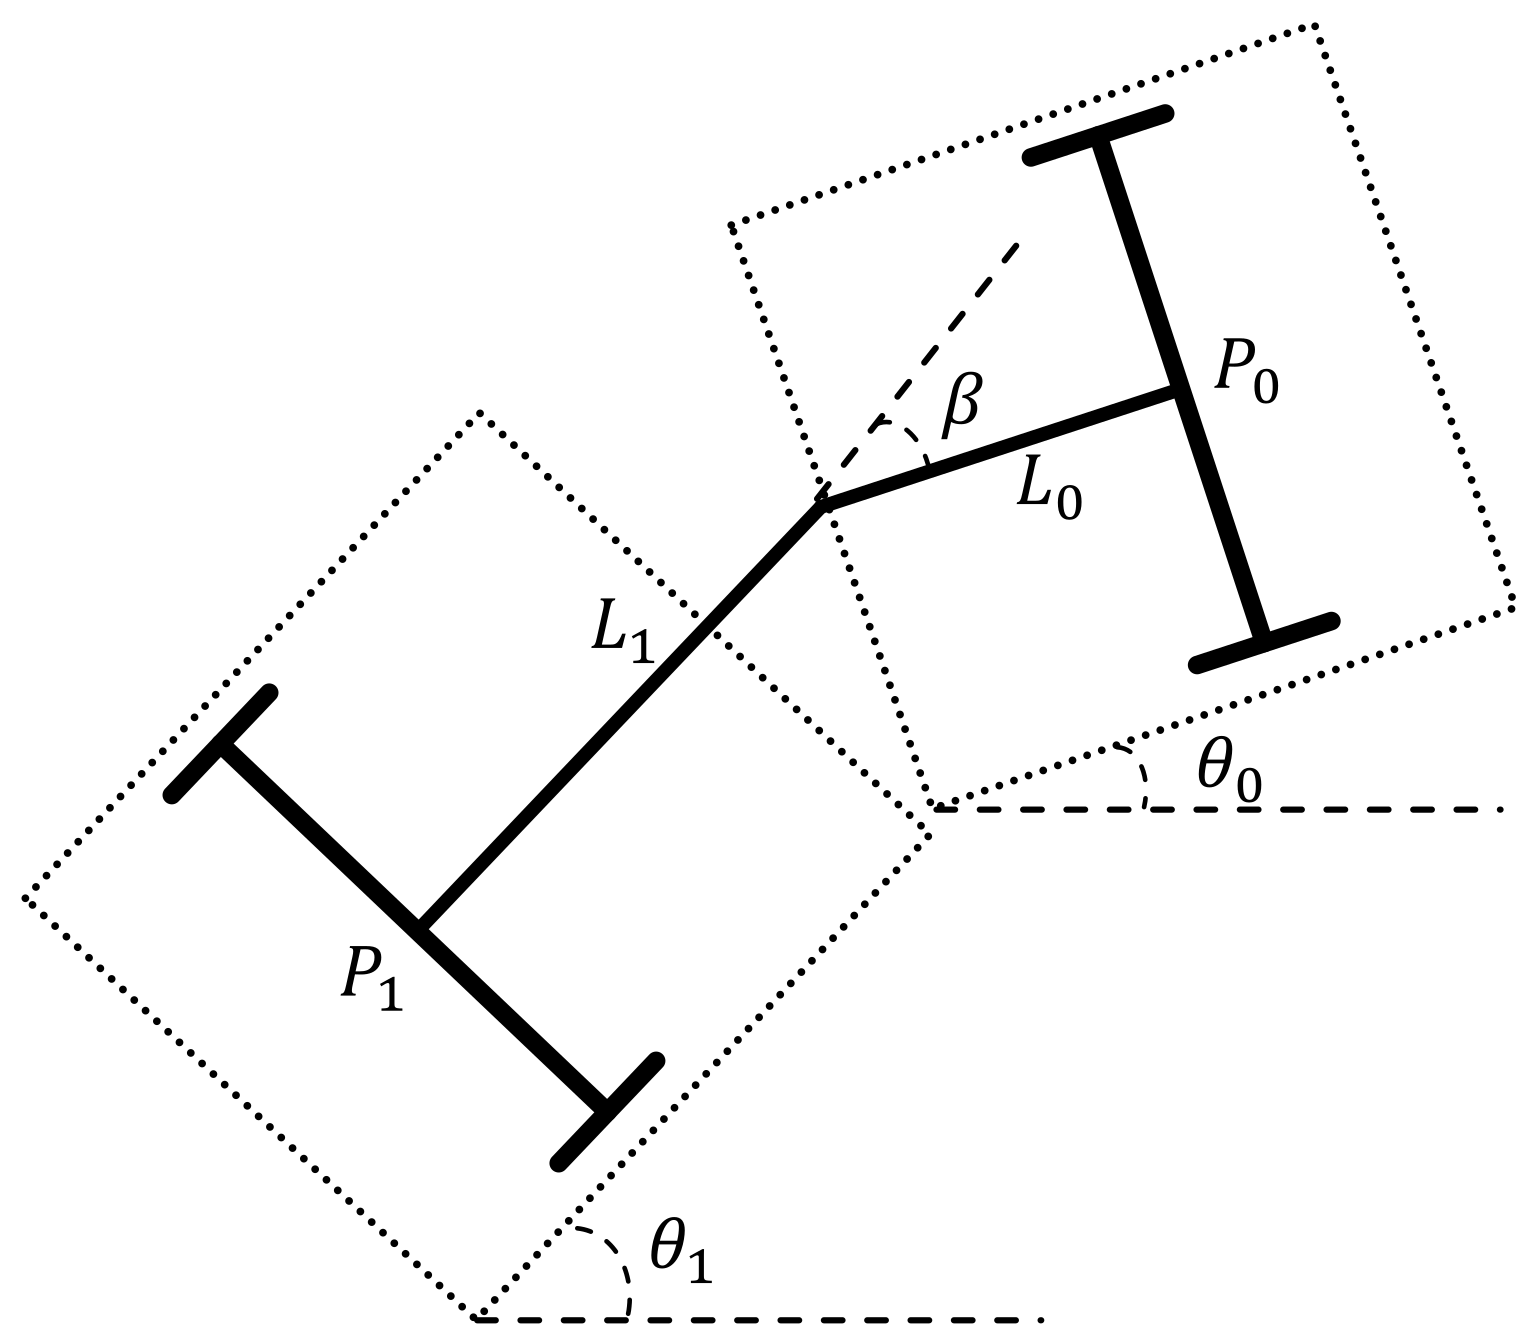
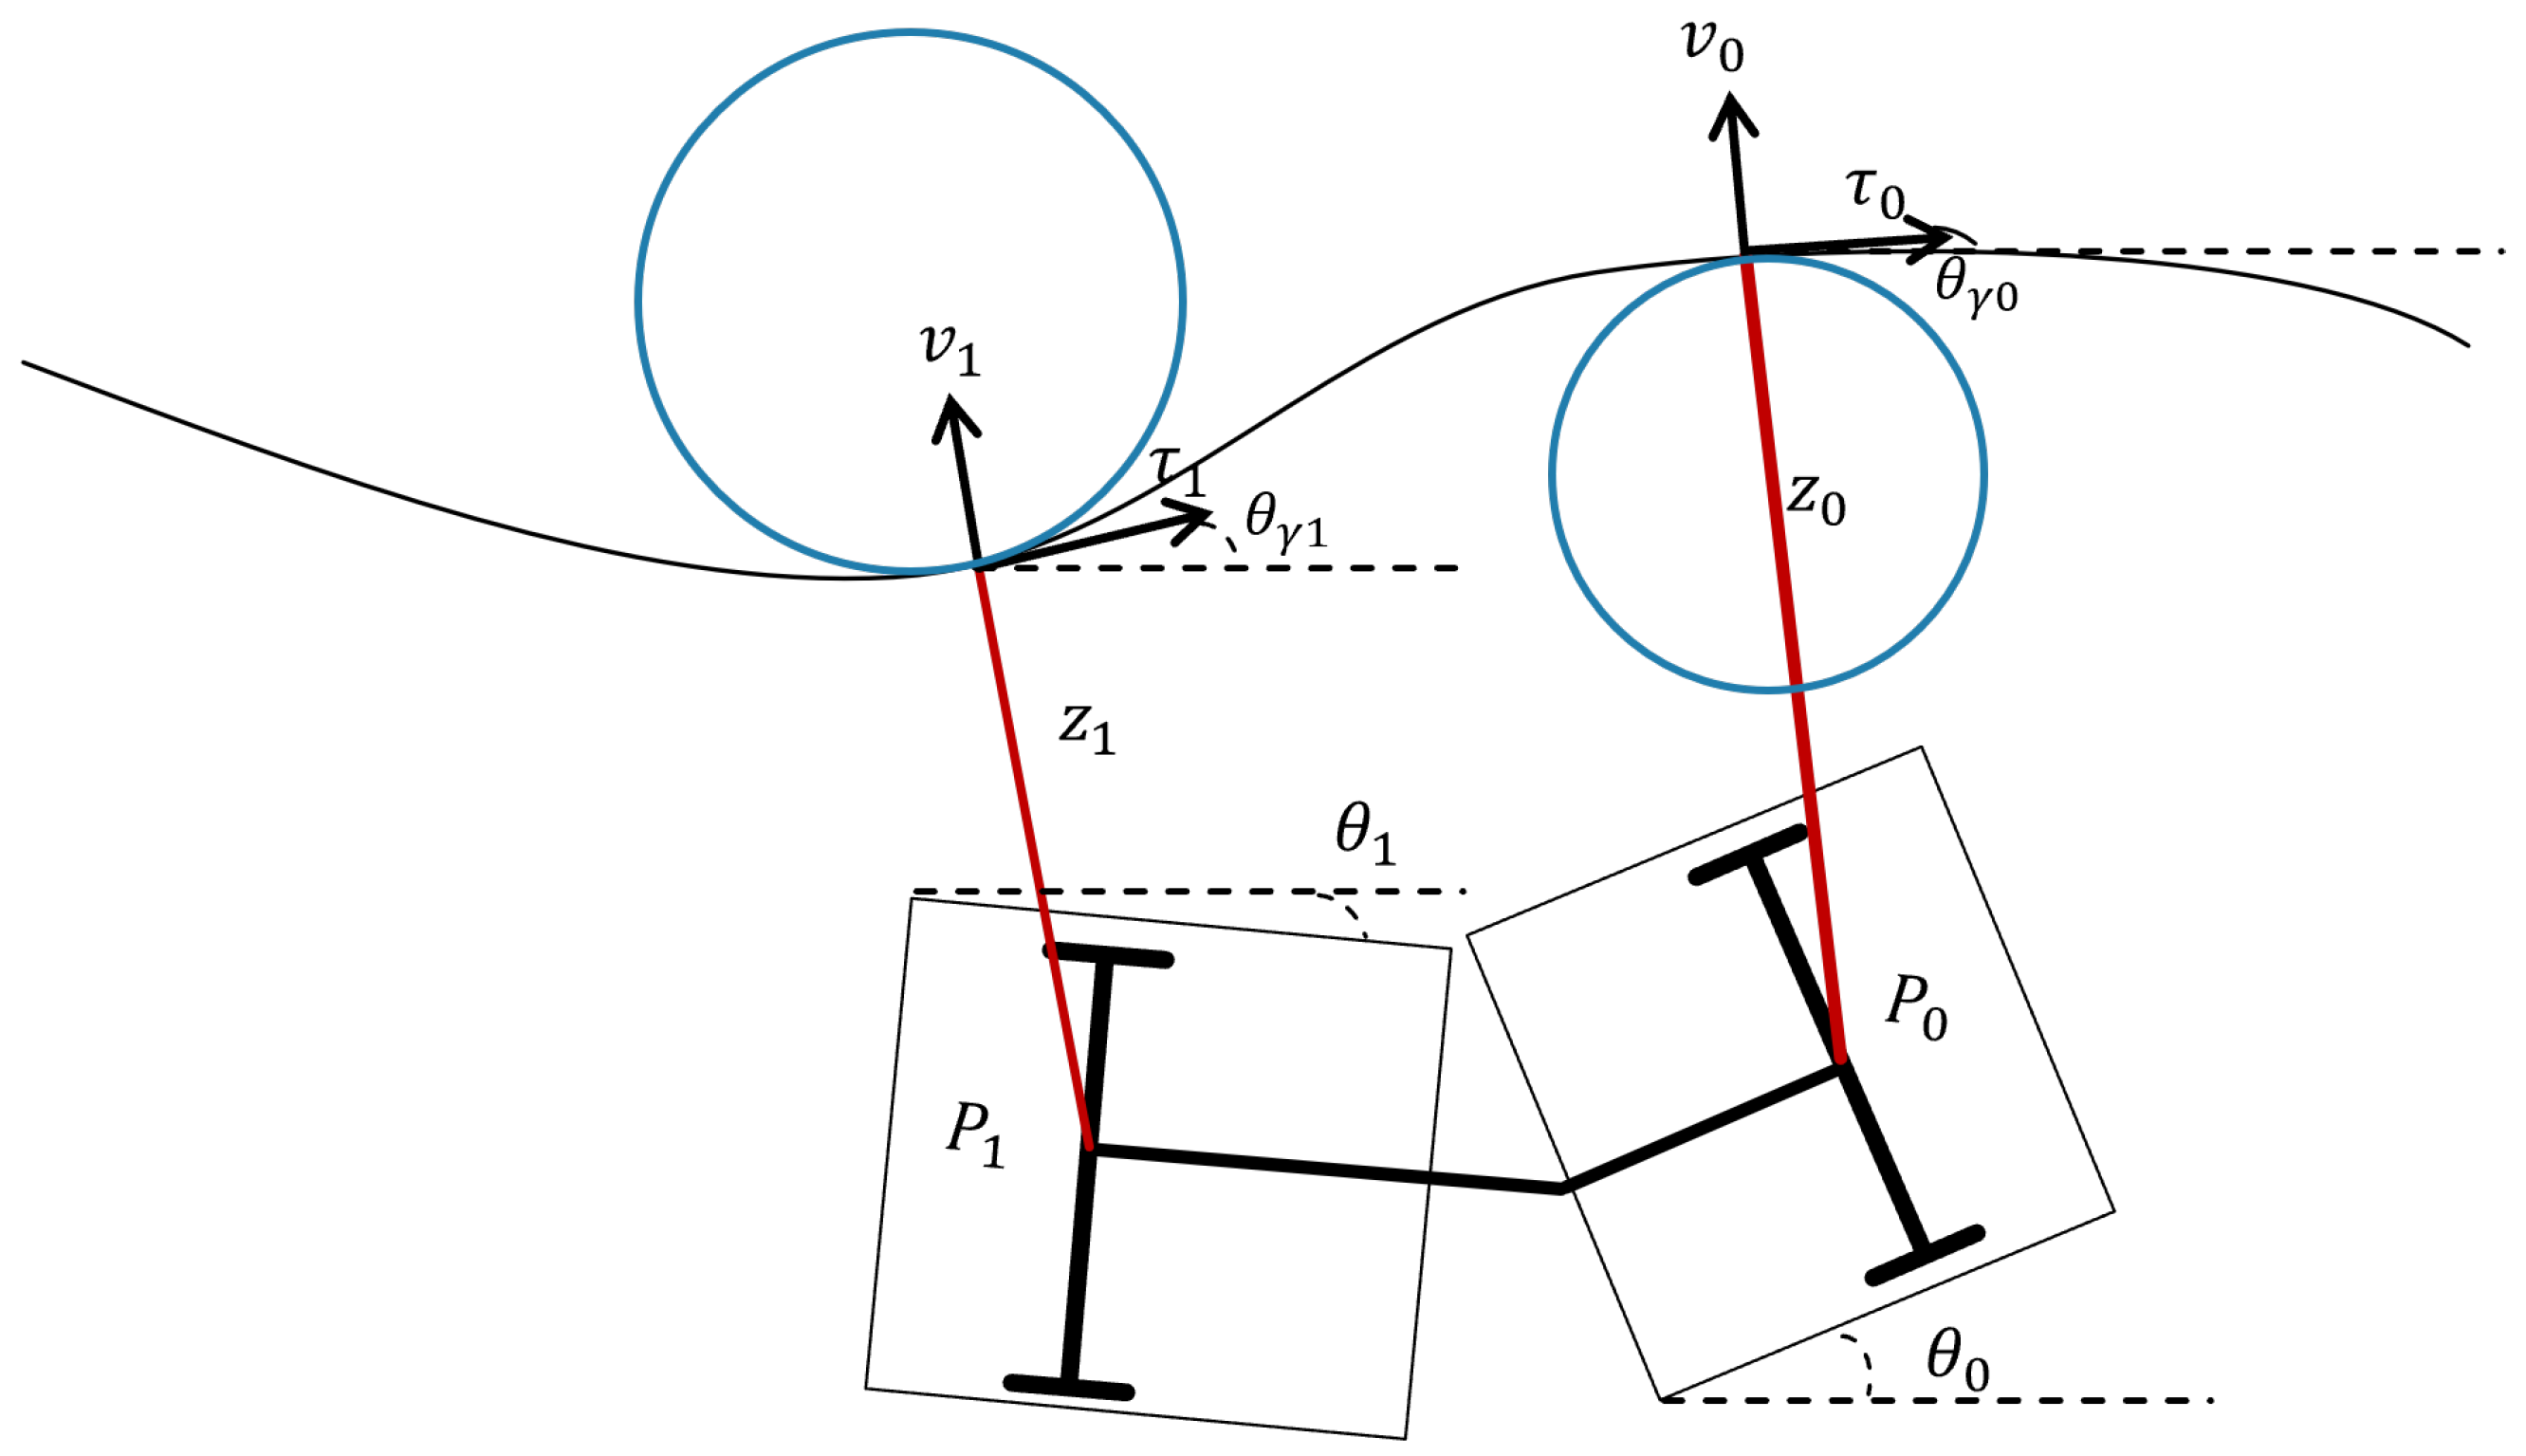
Many trucks are used for a class of activities involving a sequence of basic load-haul-dump operations. The repetitiveness of this operation has been an enabler for autonomous vehicle technology in efforts to increase safety and efficiency. In this paper, we present a framework for the automation of the load-haul-dump operation in a mine setting using an articulated dump truck. A simulation environment for the testing of autonomous driving algorithms is developed and a custom mining environment is generated to adapt to our simulation settings. We also present an operational decomposition of the sequence of tasks and develop a finite state machine for high-level decision making based on this decomposition. A path tracking module that considers both bodies of the articulated truck is also developed. The resulting architecture was implemented to achieve autonomy for a load-haul-dump operation in the simulated environment within a fixed path. Experiments show that the proposed FSM-path tracking system can automate the load-haul-dump operation; and that the simulation environment can support the testing and development of autonomous driving algorithms for configurations such as an articulated truck.
Keywords: automated driving system; articulated truck; finite state machine; path tracking; rigid-body modeling; simulation automated driving system; articulated truck; finite state machine; path tracking; rigid-body modeling; simulation