


Abstract
Distributed-order, space-fractional diffusion equations are used to describe physical processes that lack power-law scaling. A fourth-order-accurate, A-stable time-stepping method was developed, analyzed, and implemented to solve inhomogeneous parabolic problems having Riesz-space-fractional, distributed-order derivatives. The considered problem was transformed into a multi-term, space-fractional problem using Simpson’s three-eighths rule. The method is based on an approximation of matrix exponential functions using fourth-order diagonal Padé approximation. The Gaussian quadrature approach is used to approximate the integral matrix exponential function, along with the inhomogeneous term. Partial fraction splitting is used to address the issues regarding stability and computational efficiency. Convergence of the method was proved analytically and demonstrated through numerical experiments. CPU time was recorded in these experiments to show the computational efficiency of the method.
1. Introduction
Complex processes which obey a mixture of power laws and flexible variations in space are modeled by distributed-order, space-fractional differential equations. Distributed-order, space-fractional differential equations are used to model the phenomena where the order of differentiation varies in a given range [1,2]. Due to their nonlocal properties, the distributed-order differentials can model more complex dynamical systems than the fractional-order or classical models.
Consider the following two-dimensional Riesz-space, distributed-order, fractional, inhomogeneous diffusion equation:
with initial condition
and boundary condition
where . The coefficients P and Q are non-negative functions defined on , that are not identically zero and satisfy
The inhomogeneous source term f is assumed to be sufficiently smooth. The distributed-order, space-fractional derivative terms are approximated using Simpson’s three-eighth rule. For any , the two-sided, Riesz-space-fractional derivative operator on a finite interval is given by
where is the left Riemann–Liouville and is the right Riemann–Liouville fractional derivatives, which are, respectively,
The Riesz-space-fractional derivative operator on is defined similarly.
A recent review article [3] provided a state-of-the-art introduction to the mathematics of distributed-order fractional calculus, along with analytical and numerical methods. An extensive overview of the applications of distributed-order fractional calculus with applications to viscoelasticity, transport processes, and control theory have been discussed.
Anomalous diffusion phenomena take place in many complex systems, such as subsurface flows, human tissues, viscoelastic material, and plasma. In such systems, the diffusion is slower or faster than normal, the probability density function is not anymore Gaussian, and the mean-square displacement is not linear in time; see, for example, [4] and references therein. As such, the predictions obtained through integer-order local models do not match the collected data and observed behaviors. Riesz-space-fractional diffusion equations provide a powerful mathematical tool for modeling such phenomena. In these models, the diffusion rate depends on the global state of the field. In particular, the order of the Riesz fractional derivatives identifies the power-law scaling of the physical process.
Many physical processes, however, lack power-law scaling and cannot be characterized by specific scaling exponents. Among these processes are several cases of accelerating super diffusion [5,6,7]. These processes can easily be described by Riesz-space distributed-order fractional diffusion equations.
There are many applications of the distributed-order fractional operators. For example, applications to fields such as viscoelasticity, transport processes, and control theory were discussed by Ding et al. in [3], and Patnaik et al. [8] discussed applications of variable- and distributed-order fractional operators to the dynamic analysis of nonlinear oscillators.
Analytical solutions for some problems were constructed by Caputo [5] and Sokolov et al. [6]. The well-posedness of particular classes of such problems were studied by Jia et al. [9]. Numerical solutions for distributed-order space-fractional models on bounded domains are in high demand, since analytical solutions are not in general available. Wang et al. [2] developed a second-order-accurate, implicit numerical method for one- and two-dimensional Riesz-space, distributed-order fractional advection–dispersion equations. Their method is based on use of a midpoint quadrature rule for the Riesz space distributed-order term. Li et al. [10] proposed an unconditionally stable second-order Crank–Nicolson method for a one-dimensional Riesz space distributed-order diffusion equation. The method is based on midpoint quadrature and the finite volume method. For the two-dimensional Riesz-space, distributed-order advection–diffusion equation, a Crank–Nicolson ADI, Galerkin–Legendre spectral method was developed by Zhang et al. [11]. Jia and Wang [12] designed a fast finite difference method for distributed-order, space-fractional partial differential equations on convex domains. Qiao et al. [13] analyzed the velocity distributions of the distributed/variable-order fractional Maxwell governing equations under specific conditions, and discussed the effects of different parameters on the solution.
The time-stepping methods mentioned in all the above-mentioned references are of second order. The purpose of this work was to develop a computationally efficient, strongly stable, fourth-order time-stepping method that is suitable for solving problems such as (1). The numerical method is obtained by first applying the three-eighth Simpson’s rule to the distributed-order space-fractional derivative term. Then, the multi-term fractional derivative equation is discretized in space by using the fractional centered-difference formulas introduced by Ortigueira [14]. The exact solution of the resulting semi-discretized system is written using the Duhamel’s principle [15]. This exact solution involves a matrix exponential function and the integral of a matrix exponential function, along with the inhomogeneous term. Matrix exponential functions are approximated by diagonal (2,2)-Padé approximation. The rationale behind using a diagonal (2,2)-Padé approximation is that only one algebraic system needs to be solved at each time step. Therefore, we can implement this fourth-order method with the same computational complexity as a first-order method. We utilize an approach with a class of single-step, fully discrete numerical methods developed by Brenner et al. [16], and the same approach is summarized in the book by Thomée [15].
The paper is organized as follows. The Riesz-space distributed-order fractional derivative discretization is presented in Section 2. In Section 3, the time-stepping method is developed, and an implementation algorithm is provided. The convergence theorem of the numerical method is given in Section 4. Numerical experiments are shown in Section 5. Solution profiles and convergence tables, along with CPU times, are also given in the same section. Finally, some concluding remarks are included in Section 6.
2. Distributed-Order Space-Fractional Derivative Approximation
Let and be uniform discretizations of the interval . Let and . By applying the fourth-order Simpson’s three-eighths rule to the distributed terms, we obtain
where and are the coefficients of Simpson’s three-eighths rule.
To approximate the Riesz derivatives in the right-hand sides of (3) and (4), we use the fractional centered-difference introduced by Ortigueira [14]. We consider , with as the spatial mesh points. Suppose to be a sufficiently smooth function defined for . Then, for , we have
where
If vanishes outside the interval and for , then we have
We can write this system of equations as:
with
Thus, for each , we have the space-fractional derivative approximations
Similarly, by considering the spatial nodes: , with , we obtain the following approximation:
By applying the Riesz derivative approximation to Equation (1), the following semi-discrete system is obtained:
where is an matrix, I is the identity matrix and is the vector that consists of columns of the matrix , where . The inhomogeneous term is an vector, with ,
3. Time-Stepping Method
We consider the following abstract initial value problem:
to develop the numerical method and to discuss the convergence analysis that works without dependence on the spatial mesh size; see Thomée [15] [Ch. 3, 7–9]. Using Duhamel’s principle [15], the exact solution of (11) is written as:
where the matrix exponential function is the solution which corresponds to the homogeneous problem having . First, we replace the variable t by the shifted value , and then we use the following change in variable and write the exact solution (12) as:
and setup the following recurrence formula as
where k, with for some , is the temporal step size, and temporal mesh points are given by with .
Our fourth-order A-stable method is based on the following method from [15]:
where and are the rational approximations of and , respectively. These rational approximations are uniformly bounded on the spectrum of in k and h, where h represents the spatial discretization step size. The real numbers are the Gaussian quadrature points in the interval . Our aim is to obtain a procedure which admits an optimal order-error estimate , with spatial discretization order . The real number is determined by the properties of the rational functions and , for
The time-stepping method (15) is accurate for order q if it satisfies some equivalent conditions given in [15]. The reader may consult chapter 9 of [15] to fill in various details omitted here for brevity. The accuracy of the time-stepping method (15) is defined in the following definition.
Definition 1
The following Lemma describes the accuracy of the method (15) and establishes some equivalent relations which are then used in the proof of the main results.
Lemma 1
([15] (Lemma 8.1)). The time discretization method (15) is accurate for order q if and only if
and for
or equivalently
A computationally efficient method can be developed by considering and such that they have the same denominator (the same poles). Let
be bounded on the spectrum of uniformly in h and k. The method (15) is approximated as:
For the case when , we can achieve the conditions of Lemma 1 by choosing a rational function which satisfies (16) and by selecting the distinct real numbers as Gaussian quadrature points . Then, we solve the system of equations [15]
to find . The system given in (21) is of Vandermonde type, and its determinant is not zero. The rational functions are obtained as linear combinations of the terms on the right-hand side of (21). Additionally, if is bounded for large , then the right-hand sides of (21) are small for large , and the numerator polynomials of would be of a smaller degree than their denominator polynomials for each i.
A fourth-order, A-stable method is developed by considering , where
is the fourth-order, A-acceptable (2,2)-Padé approximation of . By replacing the matrix exponential by rational (2,2)-Padé approximation and taking the Gaussian quadrature points , the system (21) can be written as:
which results in
Using these rational approximations, the method (15) is written as
The above-mentioned method (23) is of fourth-order accuracy of Lemma 1 [15] (Ch. 9), under the assumption that initial data have sufficient regularity.
3.1. Computationally Efficient Version of the Method
In order to implement the methods, it is required to compute matrix exponential functions, which would be computationally expensive and compromise the computational efficiency of the time-stepping methods. Another challenge is to invert higher-degree matrix polynomials which can cause computational difficulties due to the ill-conditioning of the spatial discretization matrix A. Use of the splitting technique not only resolves this but also results in a highly efficient method; see Khaliq, Twizell, and Voss [17] and references therein. We can write:
and the corresponding takes the form:
where c is the non real pole of and the with corresponding weights w and , respectively. All the poles and corresponding weights were computed using MAPLE 11.
3.2. Algorithm
Solve for y, and then compute , where . The poles and corresponding weights are:
4. Convergence Analysis
We present convergence in the Hilbert space case assuming A is a self-adjoint operator. We followed the approach of Brenner et al. described in [16], which is also summarized in [15] (Ch. 9]). In this analysis, we used the spaces , as defined in [15] by the norm
where are orthonormal eigenfunctions of A with corresponding positive eigenvalues . We assume to have sufficient regularity and also use the concept that the operator is said to be stable in if for , , ; see [15].
Theorem 1.
Let A be a self-adjoint operator defined on the Hilbert space ; the solution operator is stable in ; and the time discretization method (15) is accurate for order , where m is a positive integer. Suppose for , . Then, there exists a constant such that
where
Proof .
For , the error can be written as:
where the error corresponds to the homogeneous equation and is the error due to the inhomogeneous part of the method. The error is approximated by the established result in [15] (Theorem 7.2) as:
By adding and subtracting in the error term and rearranging the terms, we get
Using the change of variable , we can write
and
Additionally, using the facts:
commutes with and is a q-th order approximation of . We get the following estimate:
which is bounded by the right-hand side of (24). Using Taylor-series expansions of and and the approach given in [15] (Theorem 8.1), an estimate for can be obtained as follows:
5. Numerical Experiments
In this section, we present the solutions of two test problems and discuss the results obtained. The errors between the consecutive solutions were calculated by decreasing the time step size by half. The following formula was used to calculate the rate of convergence:
where denotes the error between the consecutive solutions corresponding to the numbers of time steps k and , respectively. The are computed by using the norm. The rate of convergence of the method is computed using this approach when an analytical solution of the problem is not available.
5.1. Example 1
First we consider the following problem with ; see [10]:
with homogeneous Dirichlet boundary condition
and initial condition
where with dimensionless constants l and K. Additionally, , .
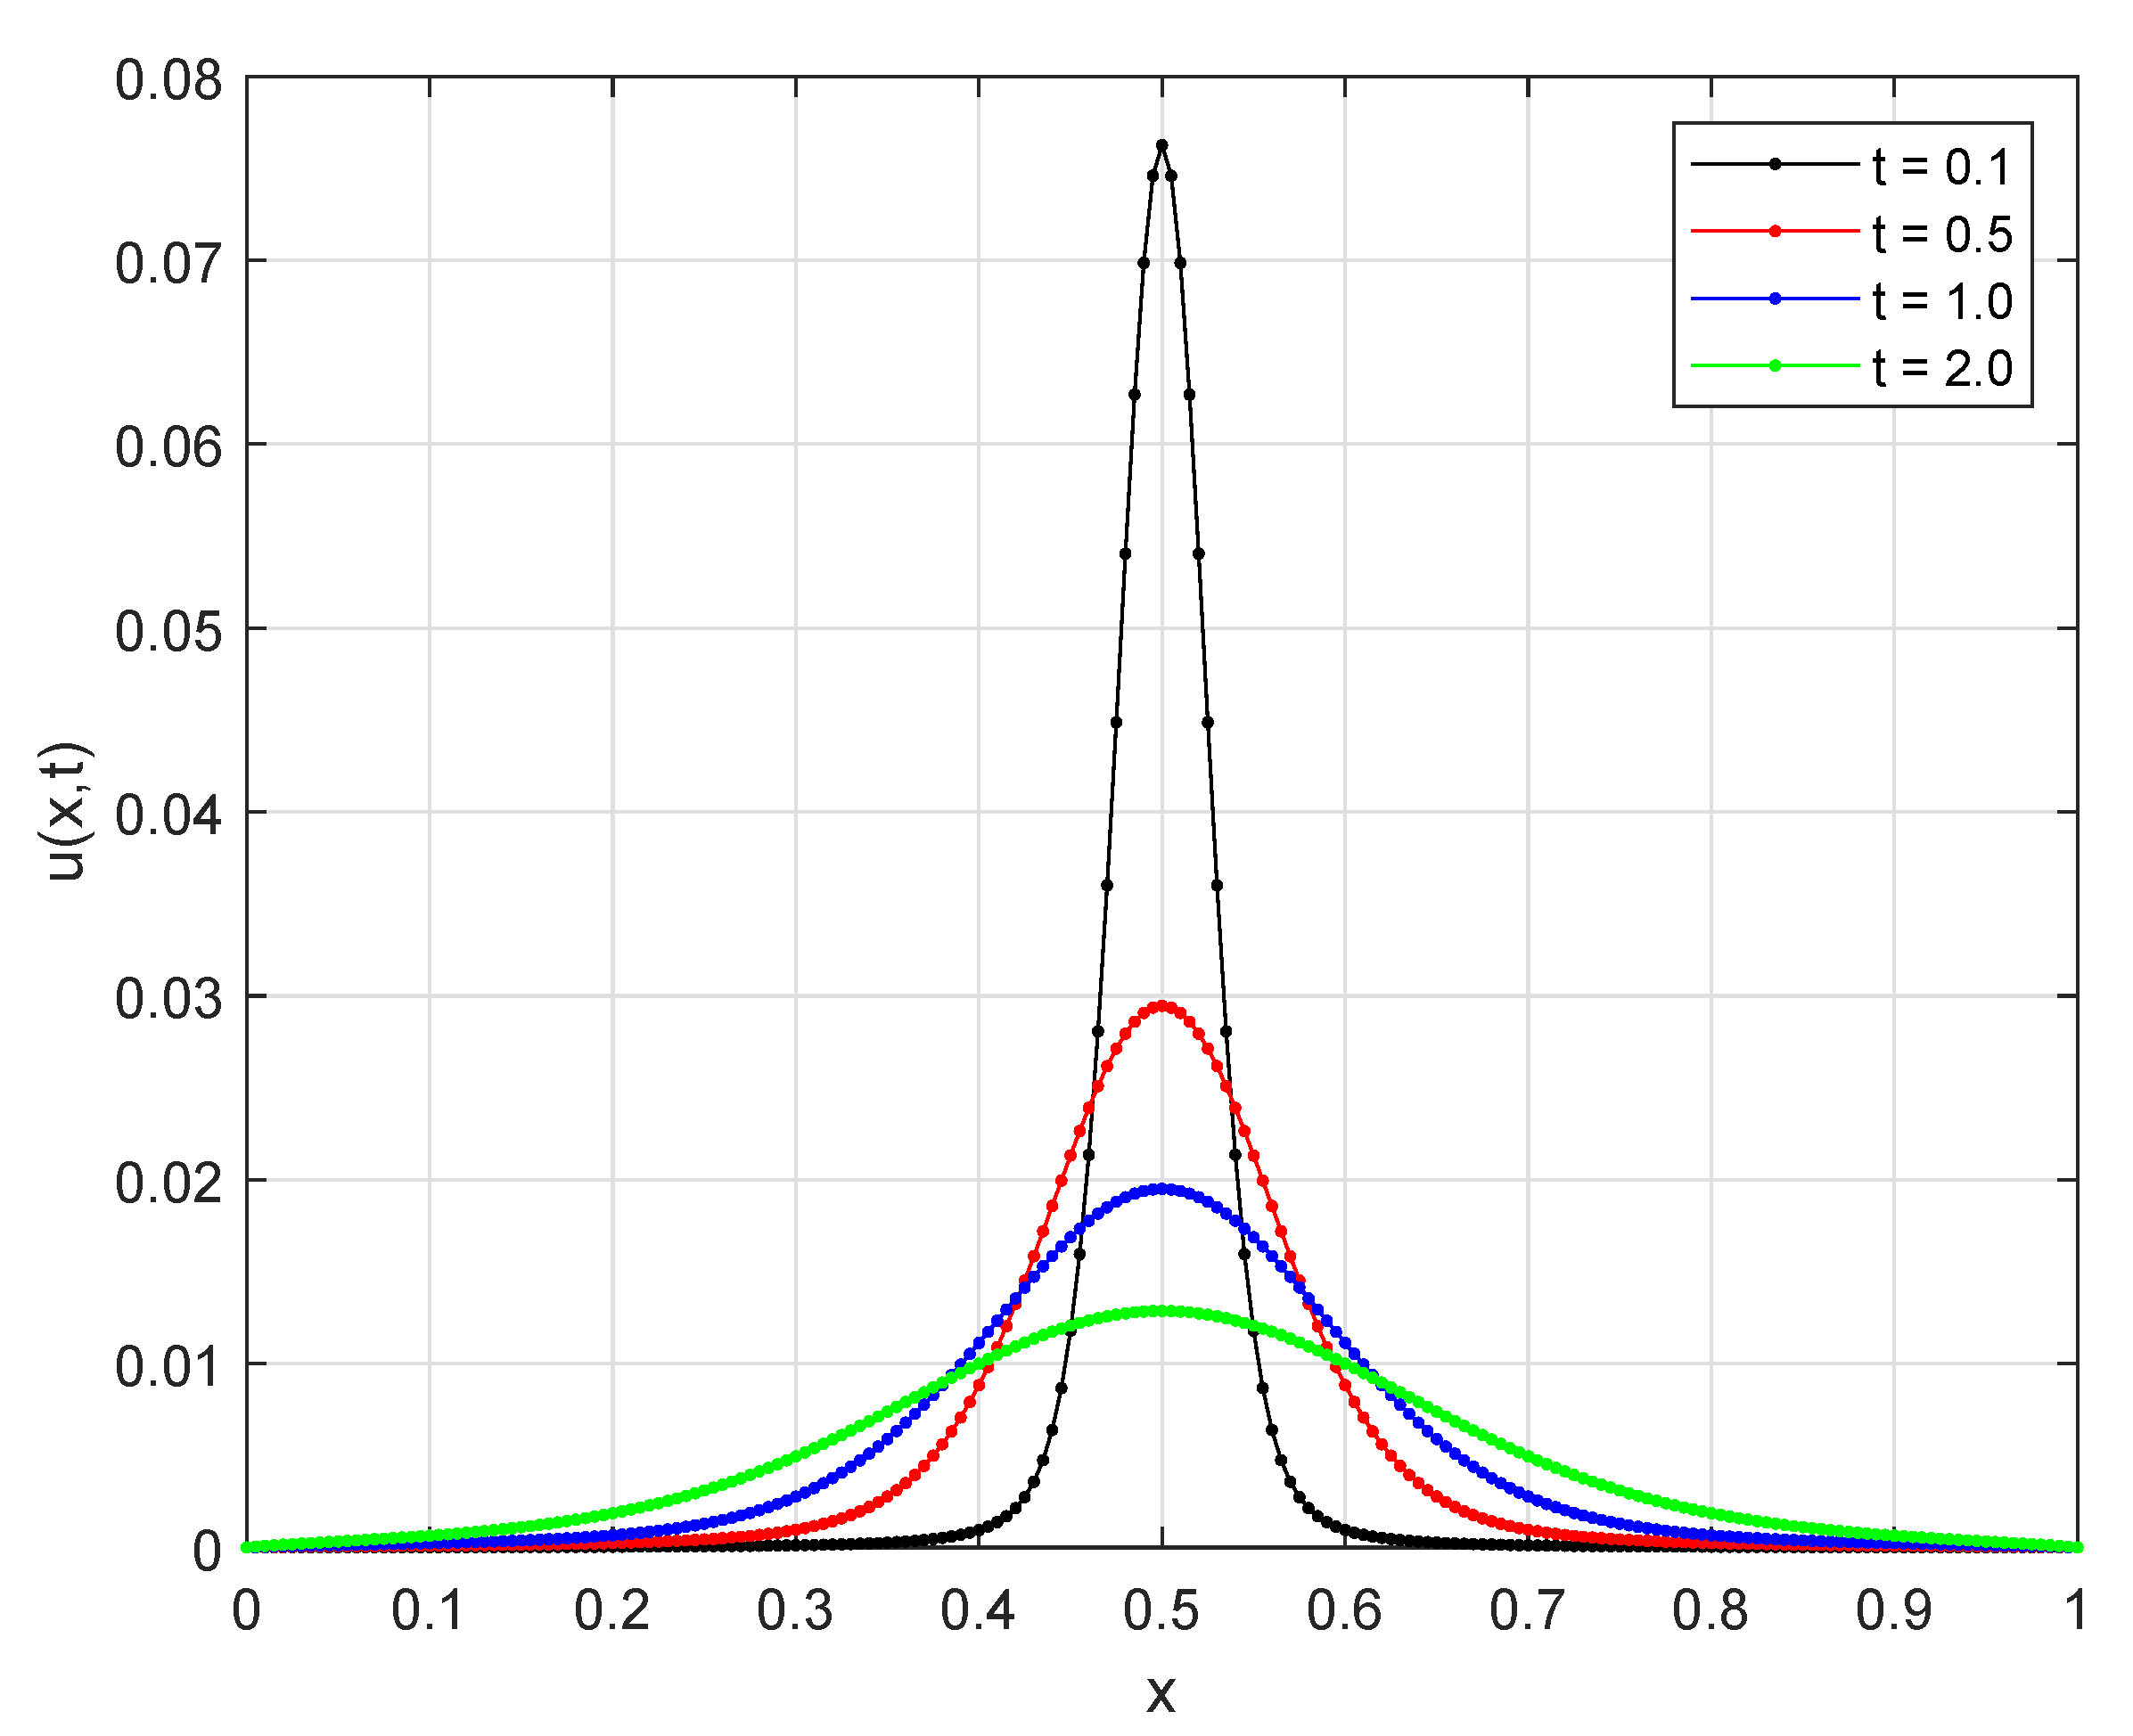
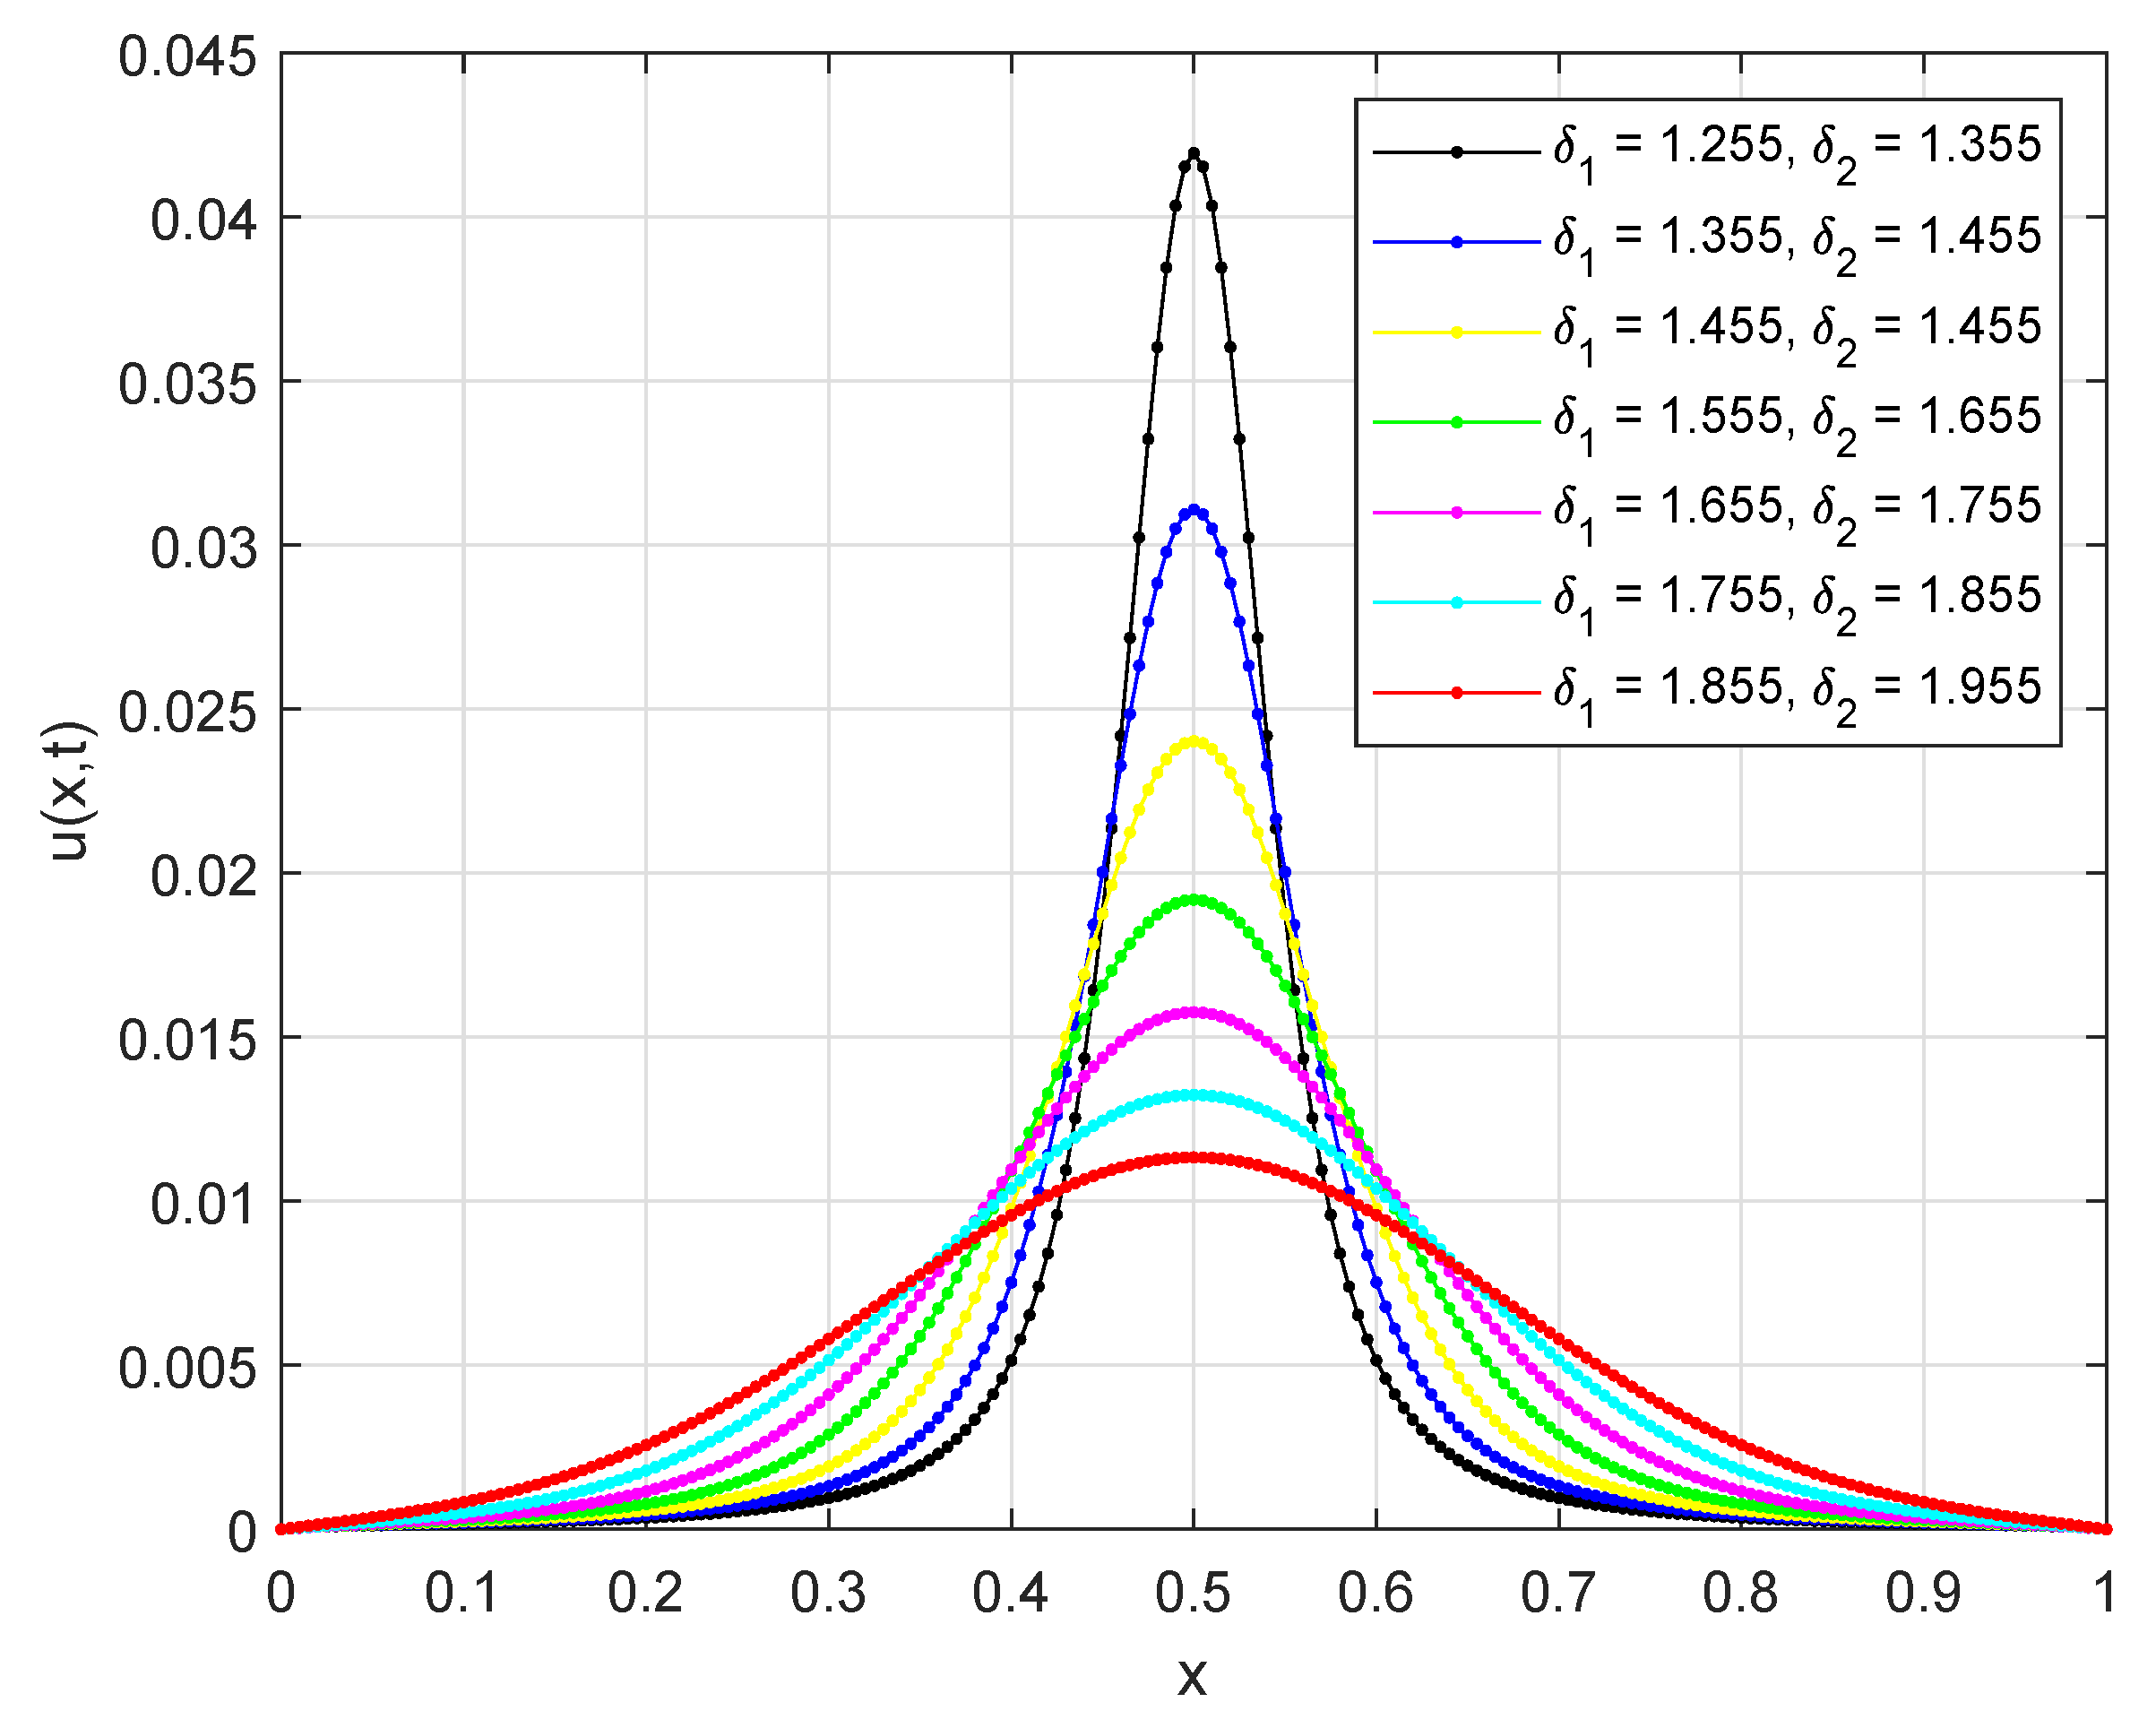
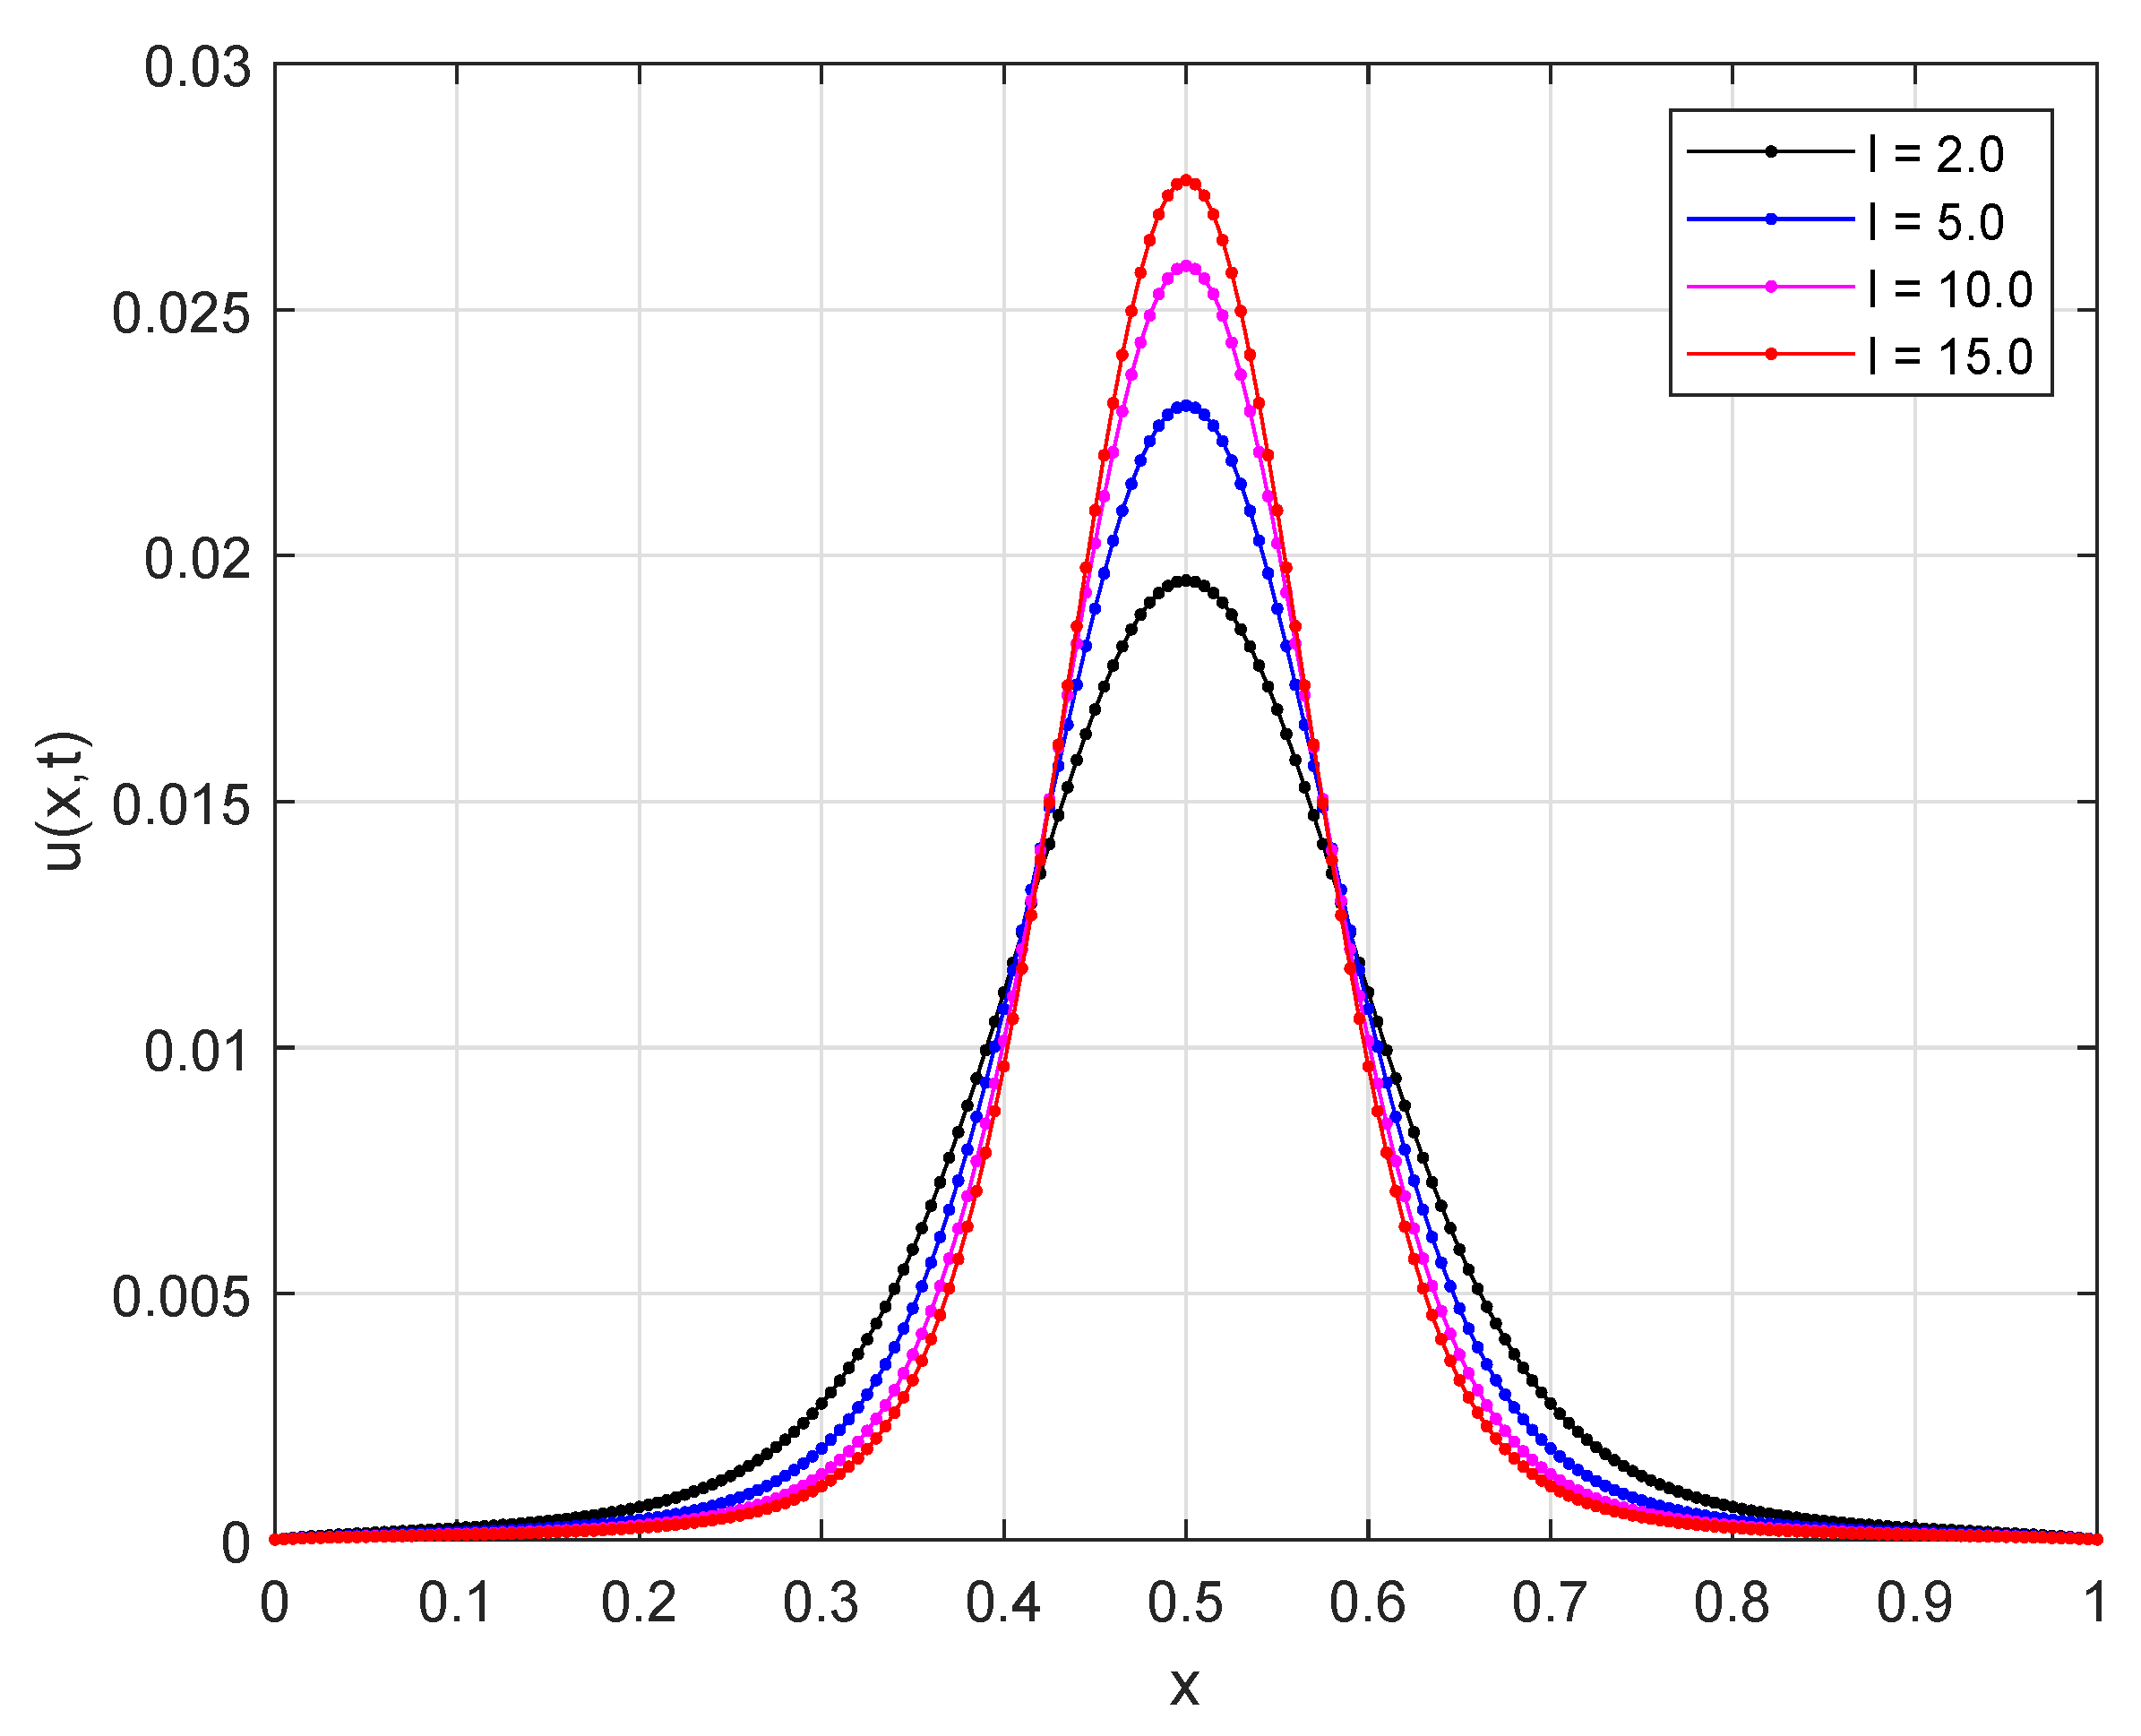
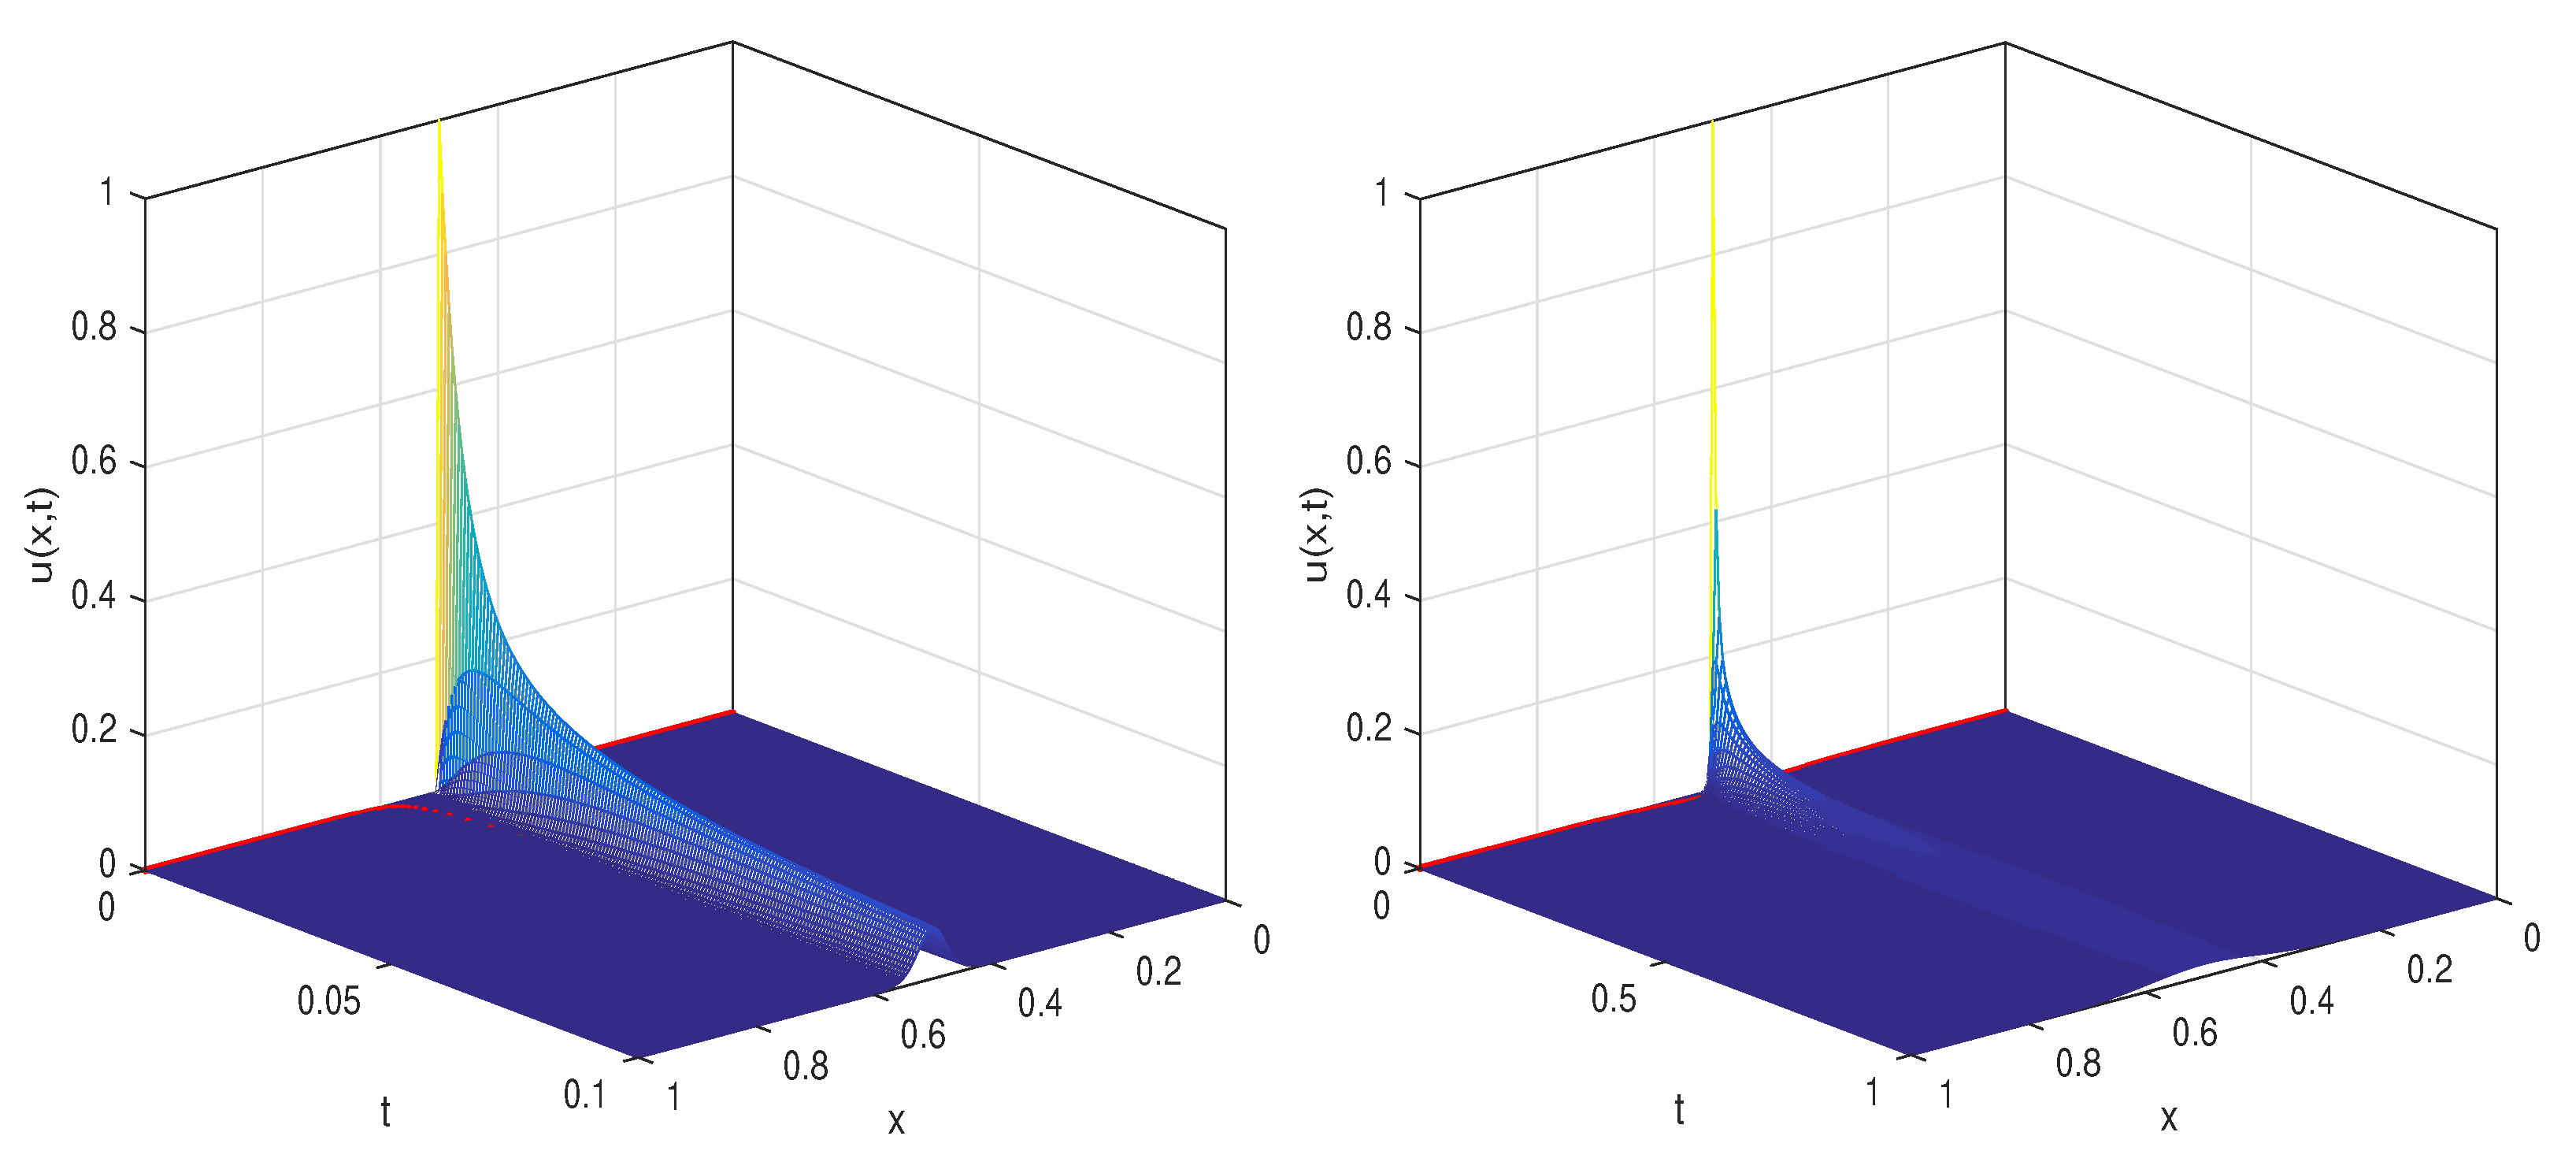
Figure 1 displays the numerical solution at different times, which decays with time. Figure 2 illustrates the impacts of and on the diffusion behavior of . As the values of and increase, the amplitude decreases and more diffusive behavior appears in the profiles. Figure 3 shows how different values of l affect the numerical solution . It is evident that the amplitude of the solution increases as the value of l increases. Figure 4 shows the time evolution graphs of at and at , respectively. Table 1 shows the error and convergence rate of the time-stepping method. A column of CPU time is also included in this table to show the computational efficiency of the method.
Figure 1.
Example 1: Numerical solutions at different values of t using , , , , , and .
Figure 2.
Example 1: Numerical solutions using for different values of and using , , , and .
Figure 3.
Example 1: Numerical solutions at using and with , , and for different values of l.
Figure 4.
Time evolution graph of Example 1 at LEFT and RIGHT, using and with , , , and .
Table 1.
Example 1: Convergence results for the time-stepping method.
5.2. Example 2
Here we consider the two-dimensional problem on the rectangular domain [1]:
with the homogeneous Dirichlet boundary condition
and the initial condition
where are non-negative functions and the inhomogeneous term is
with
The exact solution of this problem is given as: .
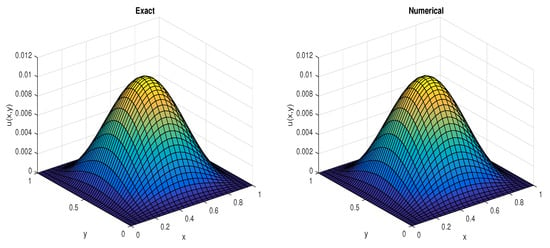
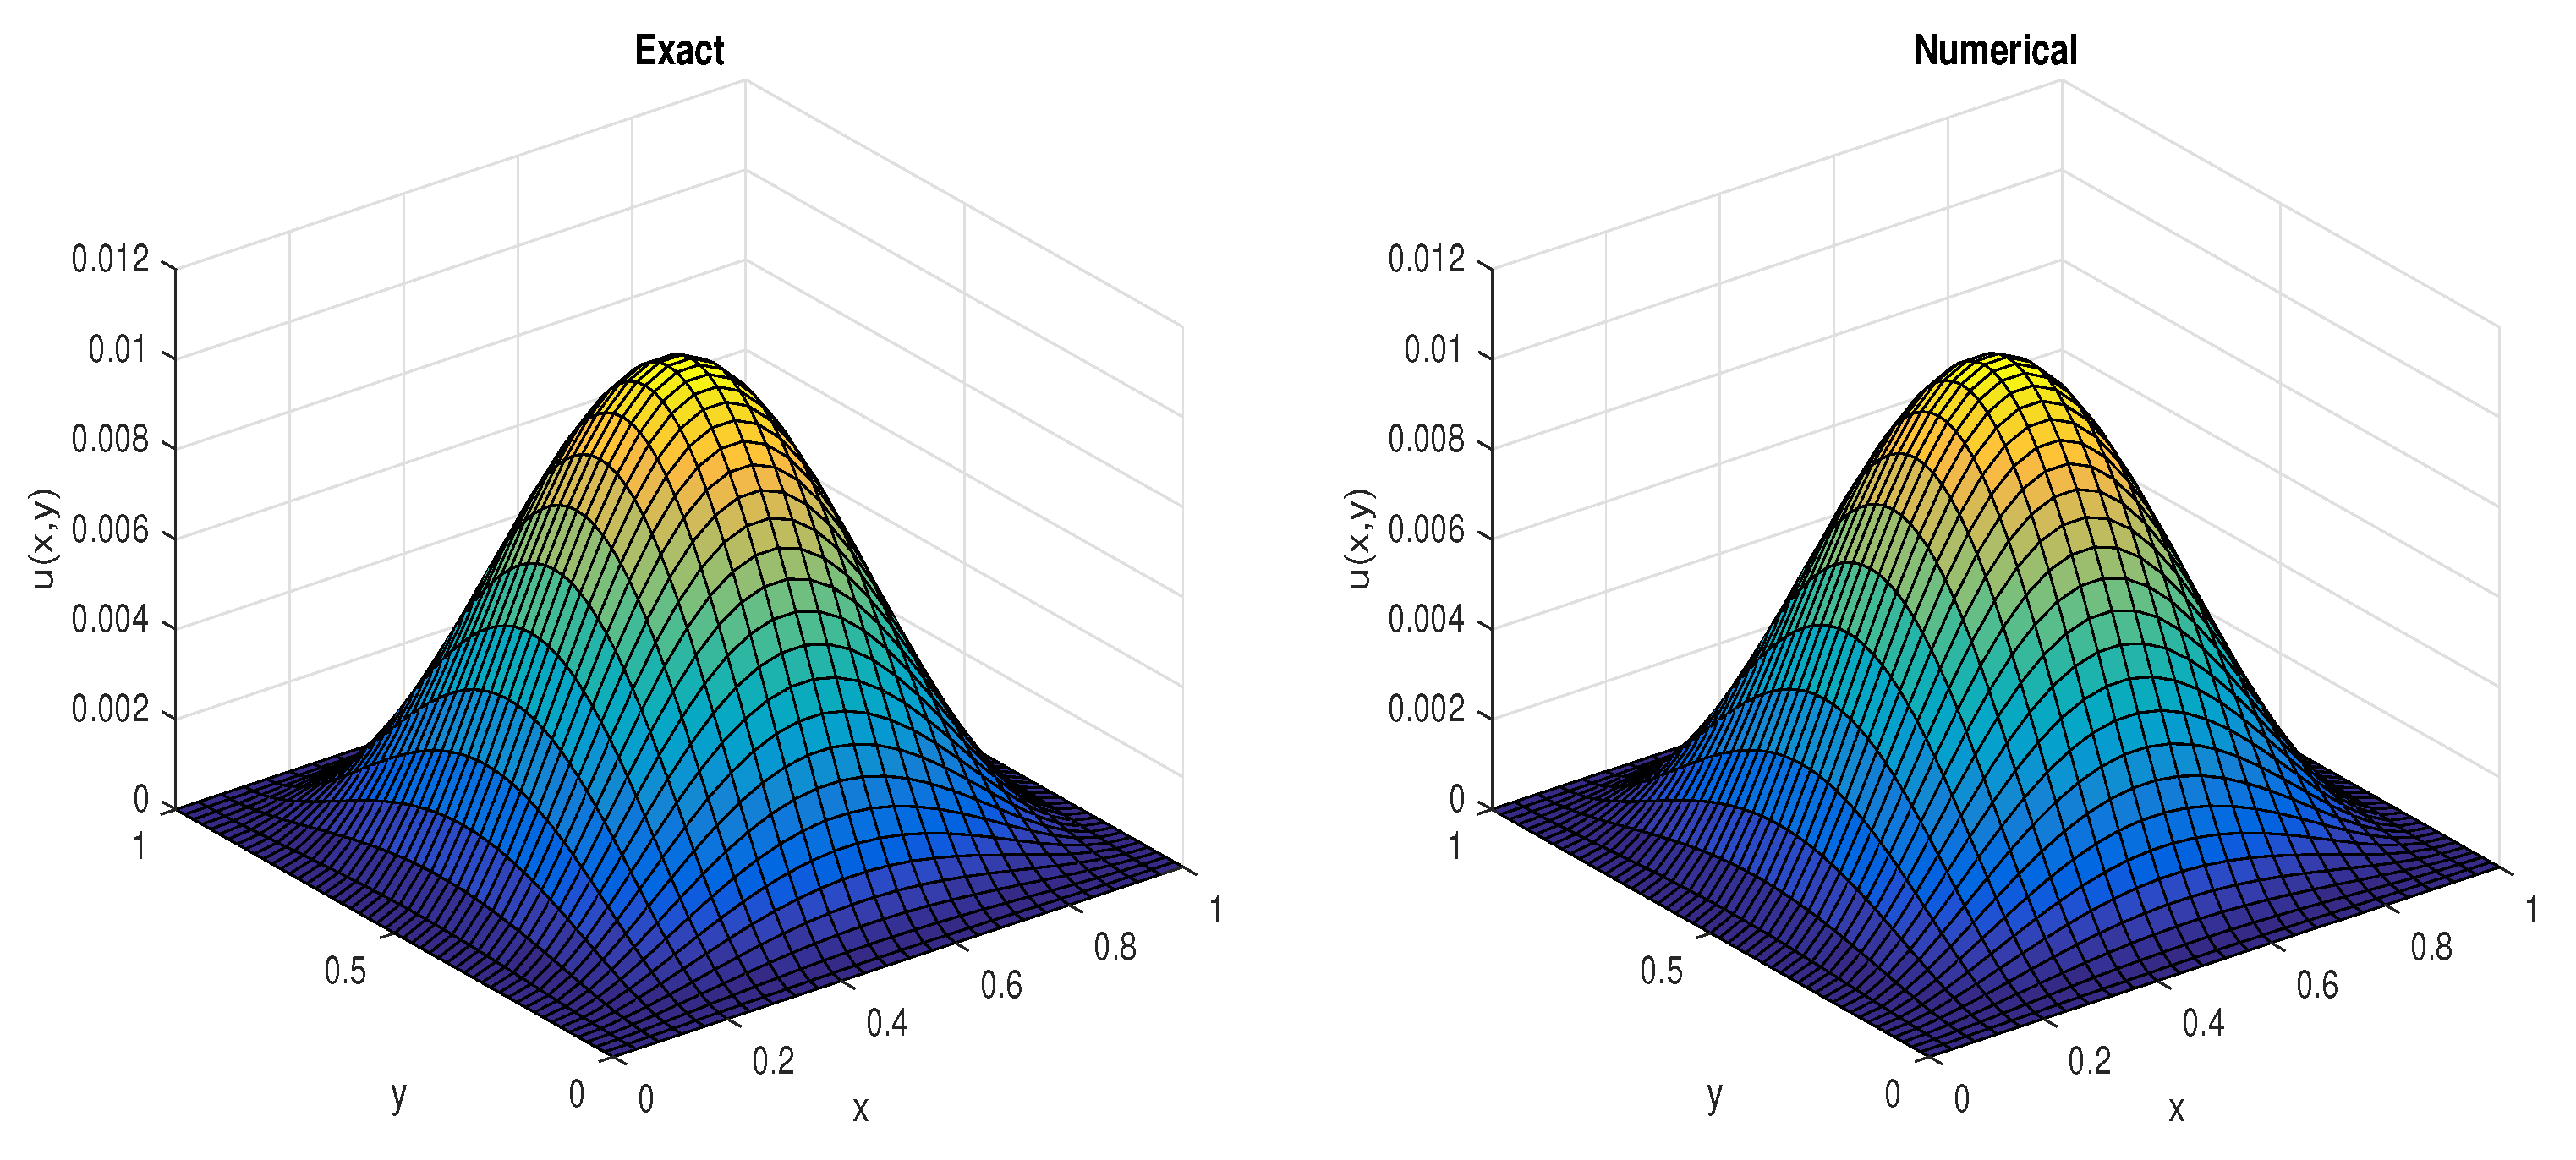
Figure 5 shows the graph’s exact and numerical solution of the problem (38). Convergence results along with CPU times are given in Table 2.
Figure 5.
Exact and numerical solutions of Example 2 with and .
Table 2.
Example 2: Convergence results for the time-stepping method.
6. Conclusions
By synthesizing diverse ideas, we developed an implementation strategy to numerically solve the Riesz distributed-order, space-fractional, inhomogeneous diffusion equations. A fourth-order A-stable method was developed using a diagonal (2,2)-Padé approximation of a matrix exponential function. Use of the partial fraction splitting makes the method more efficient, stable, and accurate. It can also be noted that we can implement this fourth-order method with the same computational complexity as a first-order method.
Author Contributions
The idea was had by A.Q.M.K.; implementation of the idea, numerical computation, proof of the theorem, and paper writing were done by M.Y.; writing—review and editing, along with very useful discussion, comments, and suggestions, were performed by K.M.F. All authors have read and agreed to the published version of the manuscript.
Funding
Thanks to King Fahd University of Petroleum & Minerals for providing publishing cost.
Data Availability Statement
Not applicable.
Acknowledgments
The support provided by the Department of Mathematics, King Fahd University of Petroleum and Minerals, is highly appreciated.
Conflicts of Interest
The authors declare no conflict of interest.
References
- Fan, W.; Li, F. A numerical method for solving the two-dimensional distributed-order space-fractional diffusion equation on an irregular convex domain. Appl. Math. Lett. 2018, 77, 114–121. [Google Scholar] [CrossRef] [Scilit]
- Wang, X.; Liu, F.; Chen, X. Novel second-order accurate implicit numerical methods for the Riesz space distributed-order advection-dispersion equations. Adv. Math. Phys. 2015, 2015, 590435. [Google Scholar] [CrossRef] [Scilit]
- Ding, W.; Patnaik, S.; Sidhardh, S.; Semperlotti, F. Applications of Distributed-Order Fractional Operators: A Review. Entropy 2021, 23, 110. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Metzler, R.; Jeon, J.H.; Cherstvy, A.G.; Barkai, E. Anomalous diffusion models and their properties: Non-stationarity, non-ergodicity, and aging at the centenary of single particle tracking. Phys. Chem. Chem. Phys. 2014, 16, 24128–24164. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Caputo, M.; Plastino, W. Diffusion in porous layers with memory. Geophys. J. Int. 2004, 158, 385–396. [Google Scholar] [CrossRef] [Scilit]
- Sokolov, I.; Chechkin, A.; Klafter, J. Distributed-order fractional kinetics. Acta Phys. Pol. B 2004, 35, 123–134. [Google Scholar]
- Umarov, S.; Steinberg, S. Random walk models associated with distributed fractional order differential equations. IMS Lect. Notes Monogr. Ser. 2006, 51, 117–127. [Google Scholar]
- Patnaik, S.; Semperlotti, F. Application of variable- and distributed-order fractional operators to the dynamic analysis of nonlinear oscillators. Nonlinear Dyn. 2020, 100, 561–580. [Google Scholar] [CrossRef] [Scilit]
- Jia, J.; Peng, J.; Li, K. Well-posedeness of abstract distributed-order fractional diffusion equations. Commun. Pure Appl. Anal. 2014, 13, 605–621. [Google Scholar] [CrossRef] [Scilit]
- Li, J.; Liu, F.; Feng, L.; Turner, I. A novel finite volume method for the Riesz space distributed-order diffusion equation. Comput. Math. Appl. 2017, 74, 772–784. [Google Scholar] [CrossRef] [Scilit]
- Zhang, H.; Liu, F.; Jiang, X.; Zeng, F.; Turner, I. A Crank-Nicolson ADI Galerkin-Legendre spectral method for the two-dimensional Riesz space distributed-order advection-diffusion equation. Comput. Math. Appl. 2018, 76, 2460–2476. [Google Scholar] [CrossRef] [Scilit]
- Jia, J.; Wang, H. A fast finite difference method for distributed-order space-fractional partial differential equations on convex domains. Comput. Math. Appl. 2018, 75, 2031–2041. [Google Scholar] [CrossRef] [Scilit]
- Qiao, Y.L.; Wang, X.P.; Xu, H.Y.; Qi, H.T. Numerical analysis for viscoelastic fluid flow with distributed/variable order time fractional Maxwell constitutive models. Appl. Math. Mech. 2021, 42, 1771–1786. [Google Scholar] [CrossRef] [Scilit]
- Ortigueira, M.D. Riesz potential operators and inverses via fractional centered derivatives. Int. J. Math. Sci. 2006, 2006, 048391. [Google Scholar] [CrossRef] [Scilit]
- Thomée, V. Galerkin Finite Element Methods for Parabolic Problems; Springer Series in Computational Mathematics; Springer: Berlin, Germany, 1997. [Google Scholar]
- Brenner, P.; Crouzeix, M.; Thomée, V. Single step methods for inhomogeneous linear differential equations in banach space. RAIRO Anal. Numérique 1982, 16, 5–26. [Google Scholar] [CrossRef] [Scilit]
- Khaliq, A.Q.M.; Twizell, E.H.; Voss, D.A. On parallel algorithms for semidiscretized parabolic partial differential equations based on subdiagonal Padé approximations. Numer. Methods Partial Differ. Equ. 1993, 9, 107–116. [Google Scholar] [CrossRef] [Scilit]

Publisher’s Note: MDPI stays neutral with regard to jurisdictional claims in published maps and institutional affiliations. |
© 2022 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).