Switching Adaptive Model Predictive Control for Perturbed Linear Time-Varying Systems


Abstract
1. Introduction
2. Preliminaries
Data Informativity of Switching Controllers
3. SMPC for Estimation of LTV Systems
3.1. The Time Invariant Case
3.1.1. Robust SMPC
3.1.2. Minimum Dwell Times
3.2. Extension to LTV Systems
4. Adaptive SMPC
4.1. Recursive Identification
4.2. Adaptive SMPC Algorithm
| Algorithm 1 Adaptive SMPC |
Offline:
Online:
|
5. Illustrative Example
5.1. Switching Controller Design
5.2. Non-Switching Baseline
5.3. Switching for Informativity
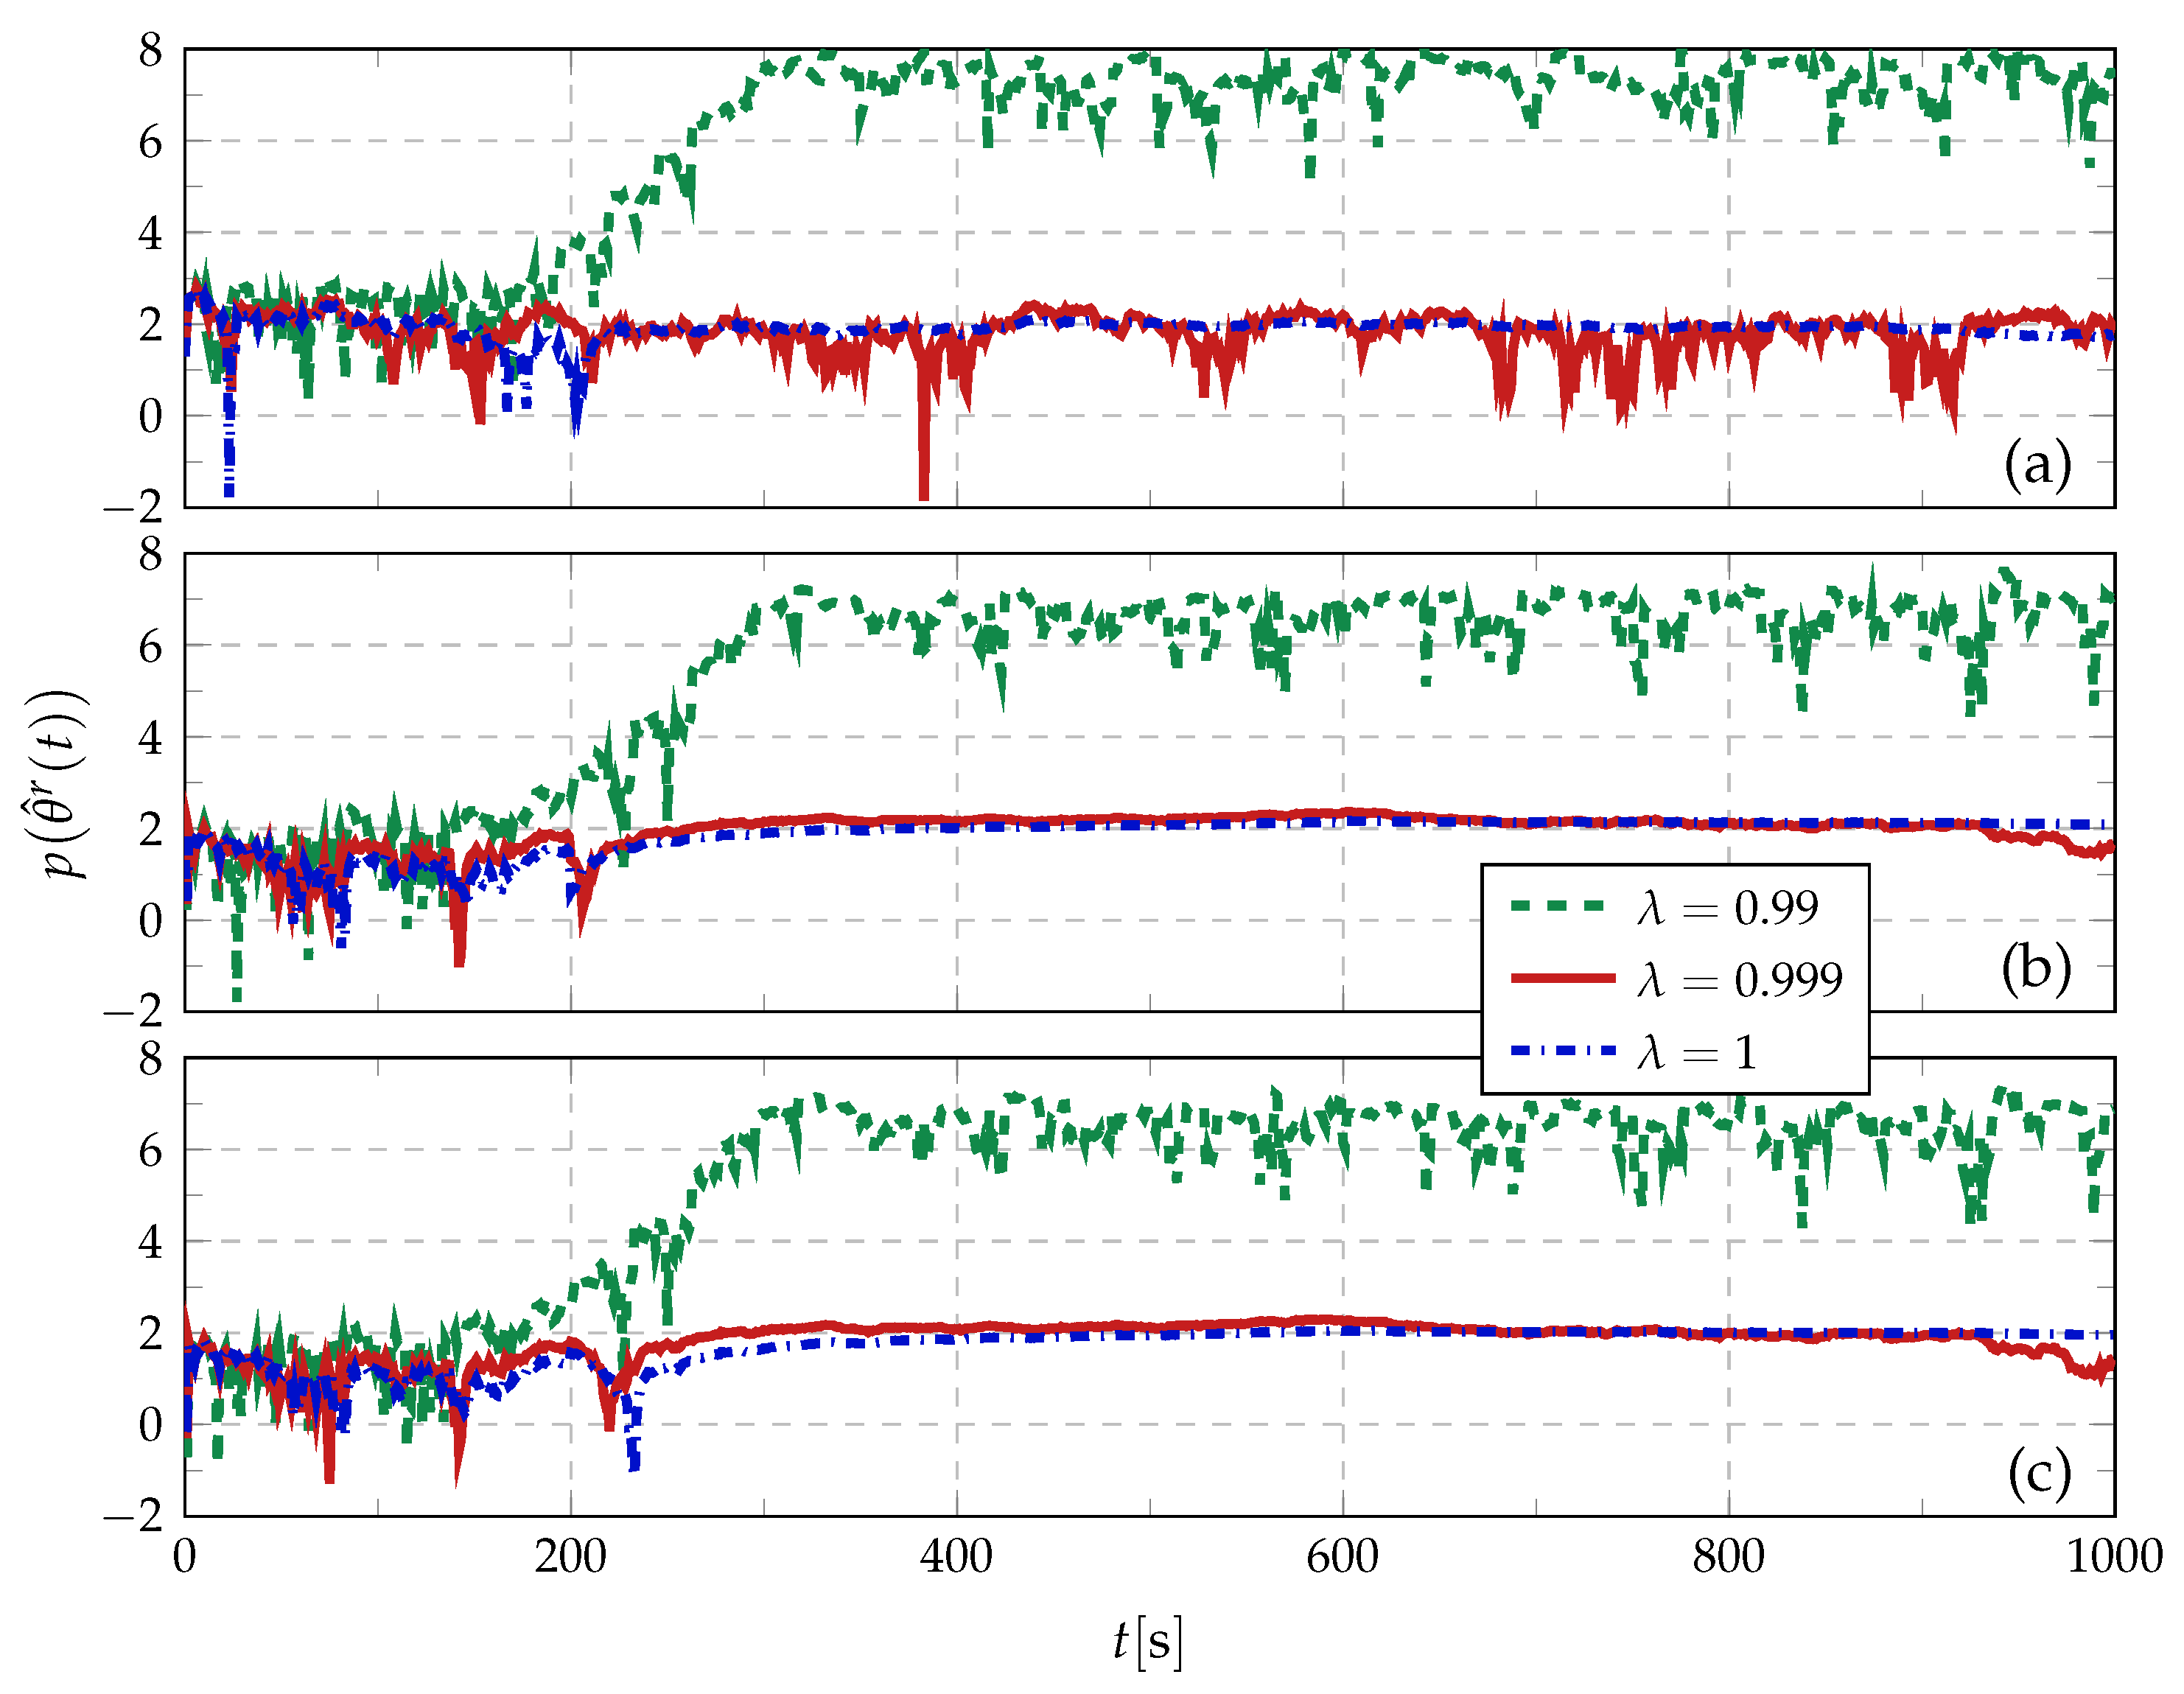
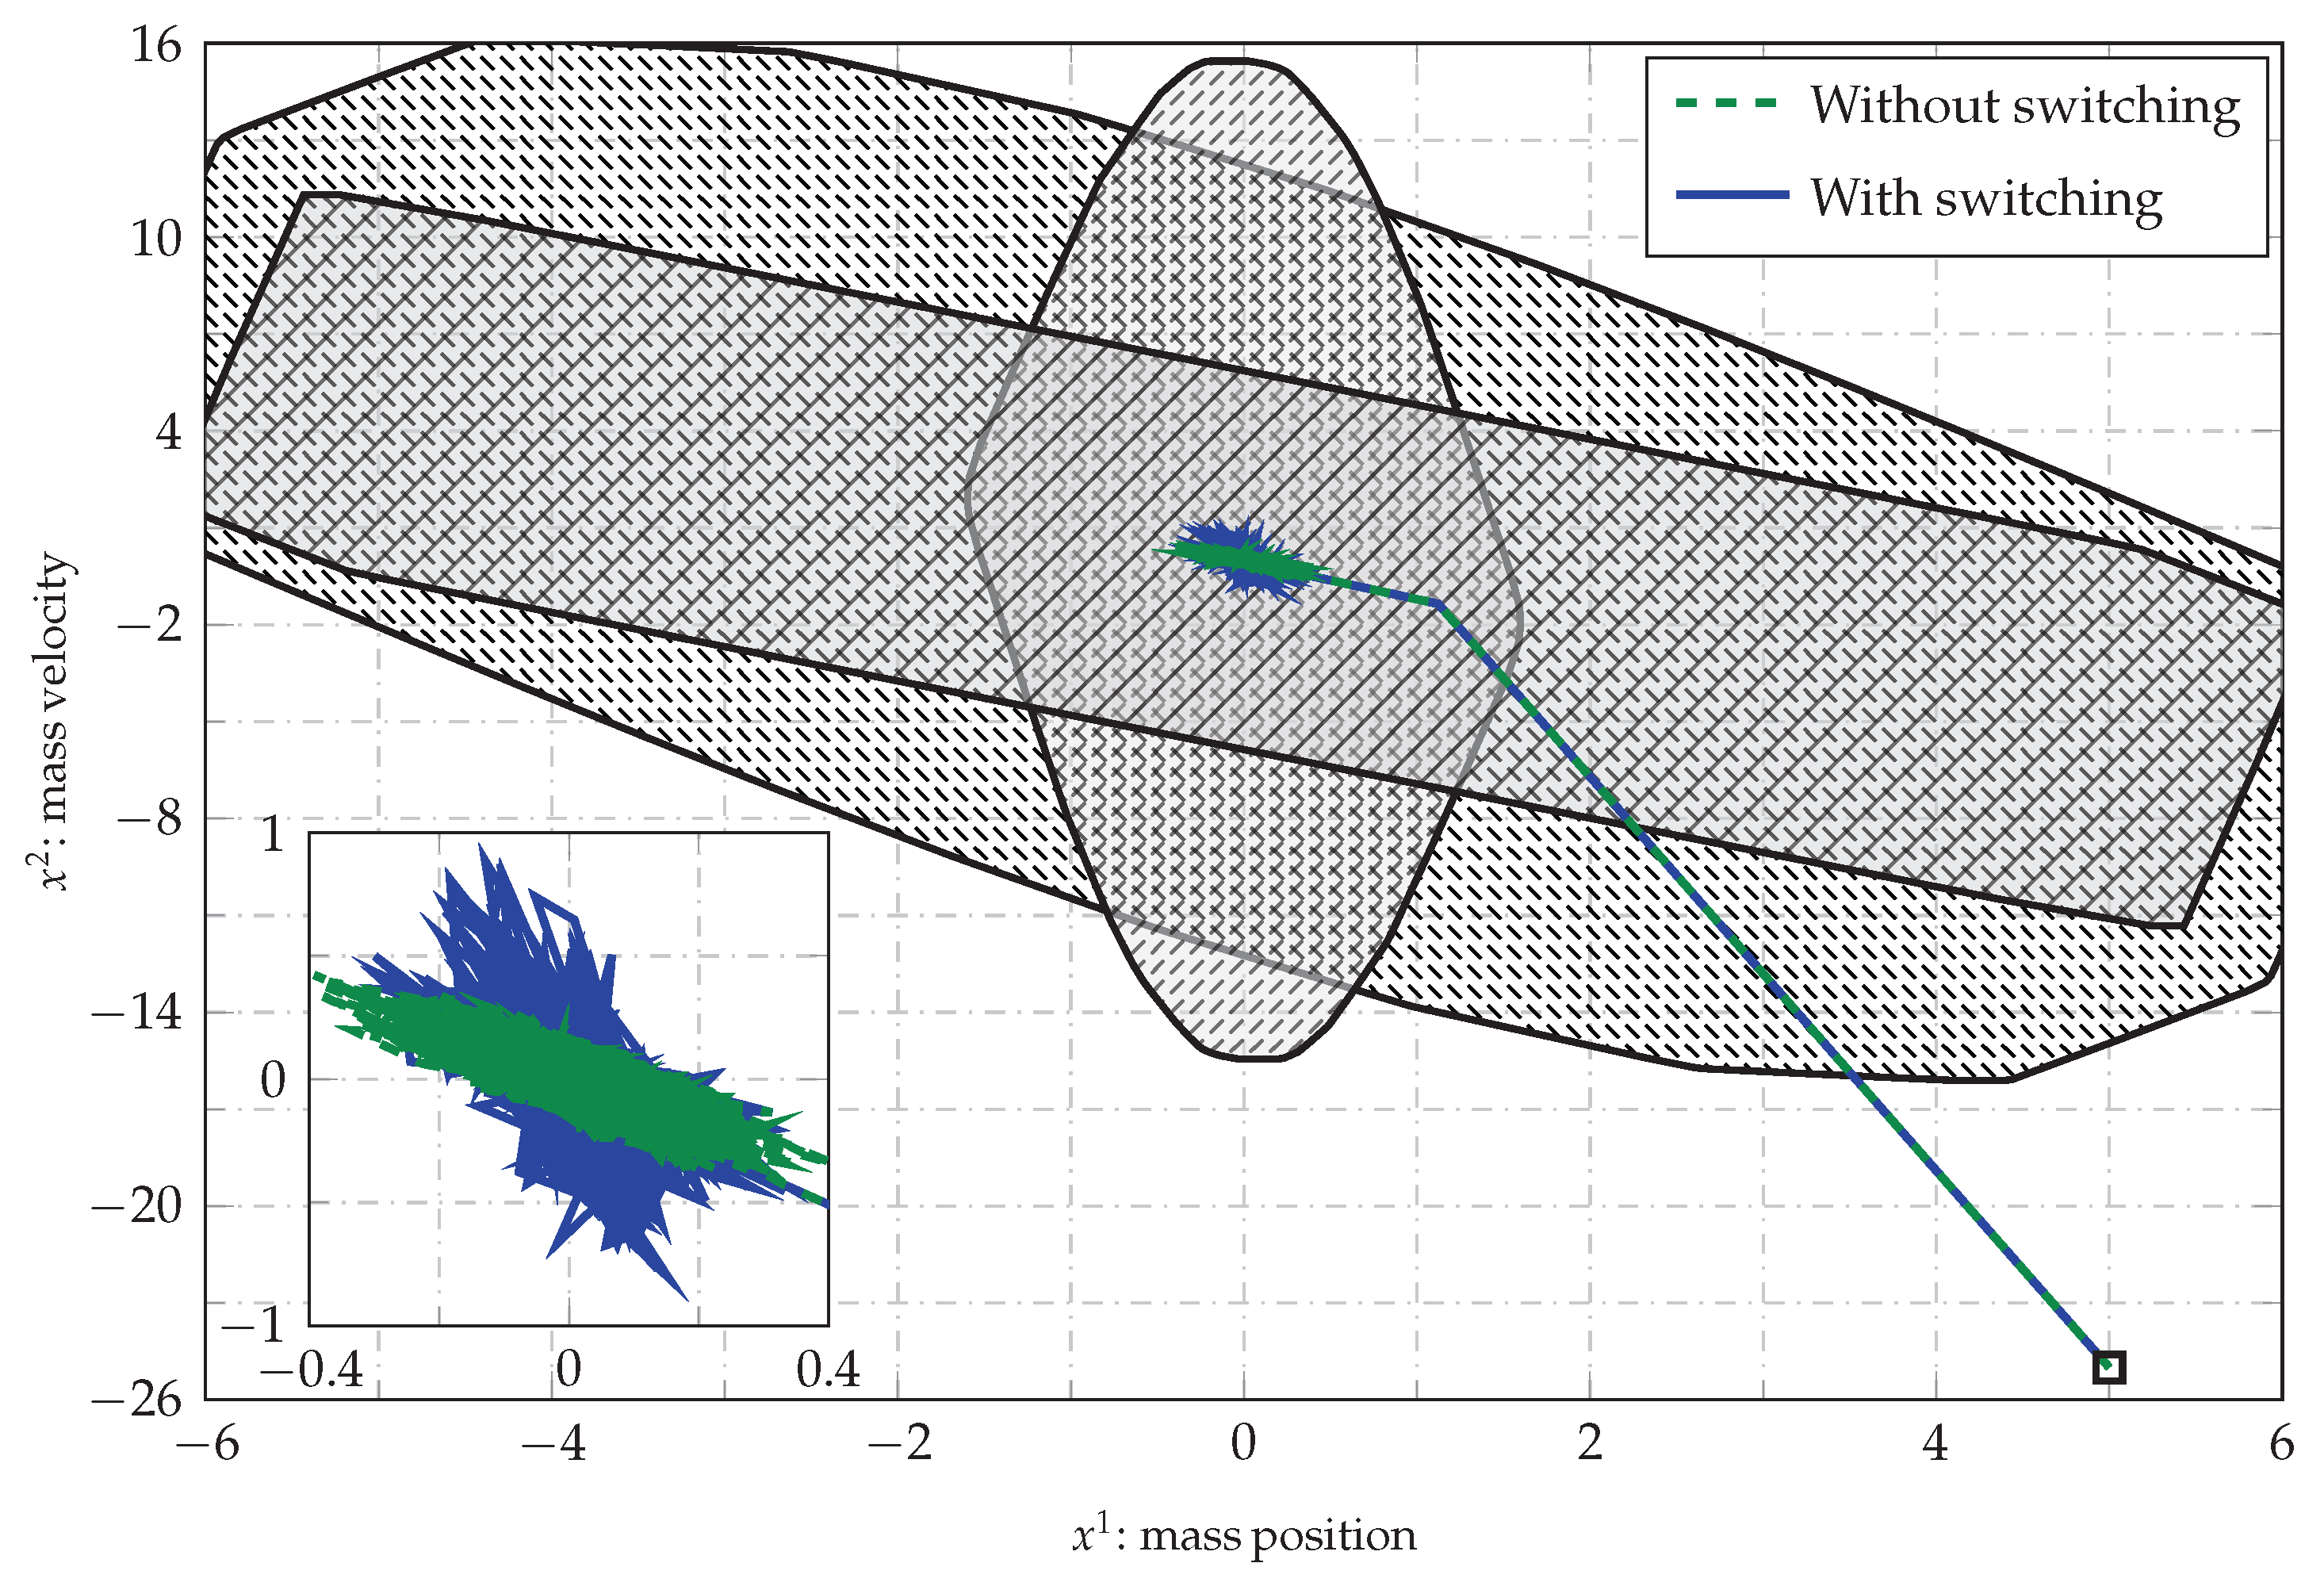
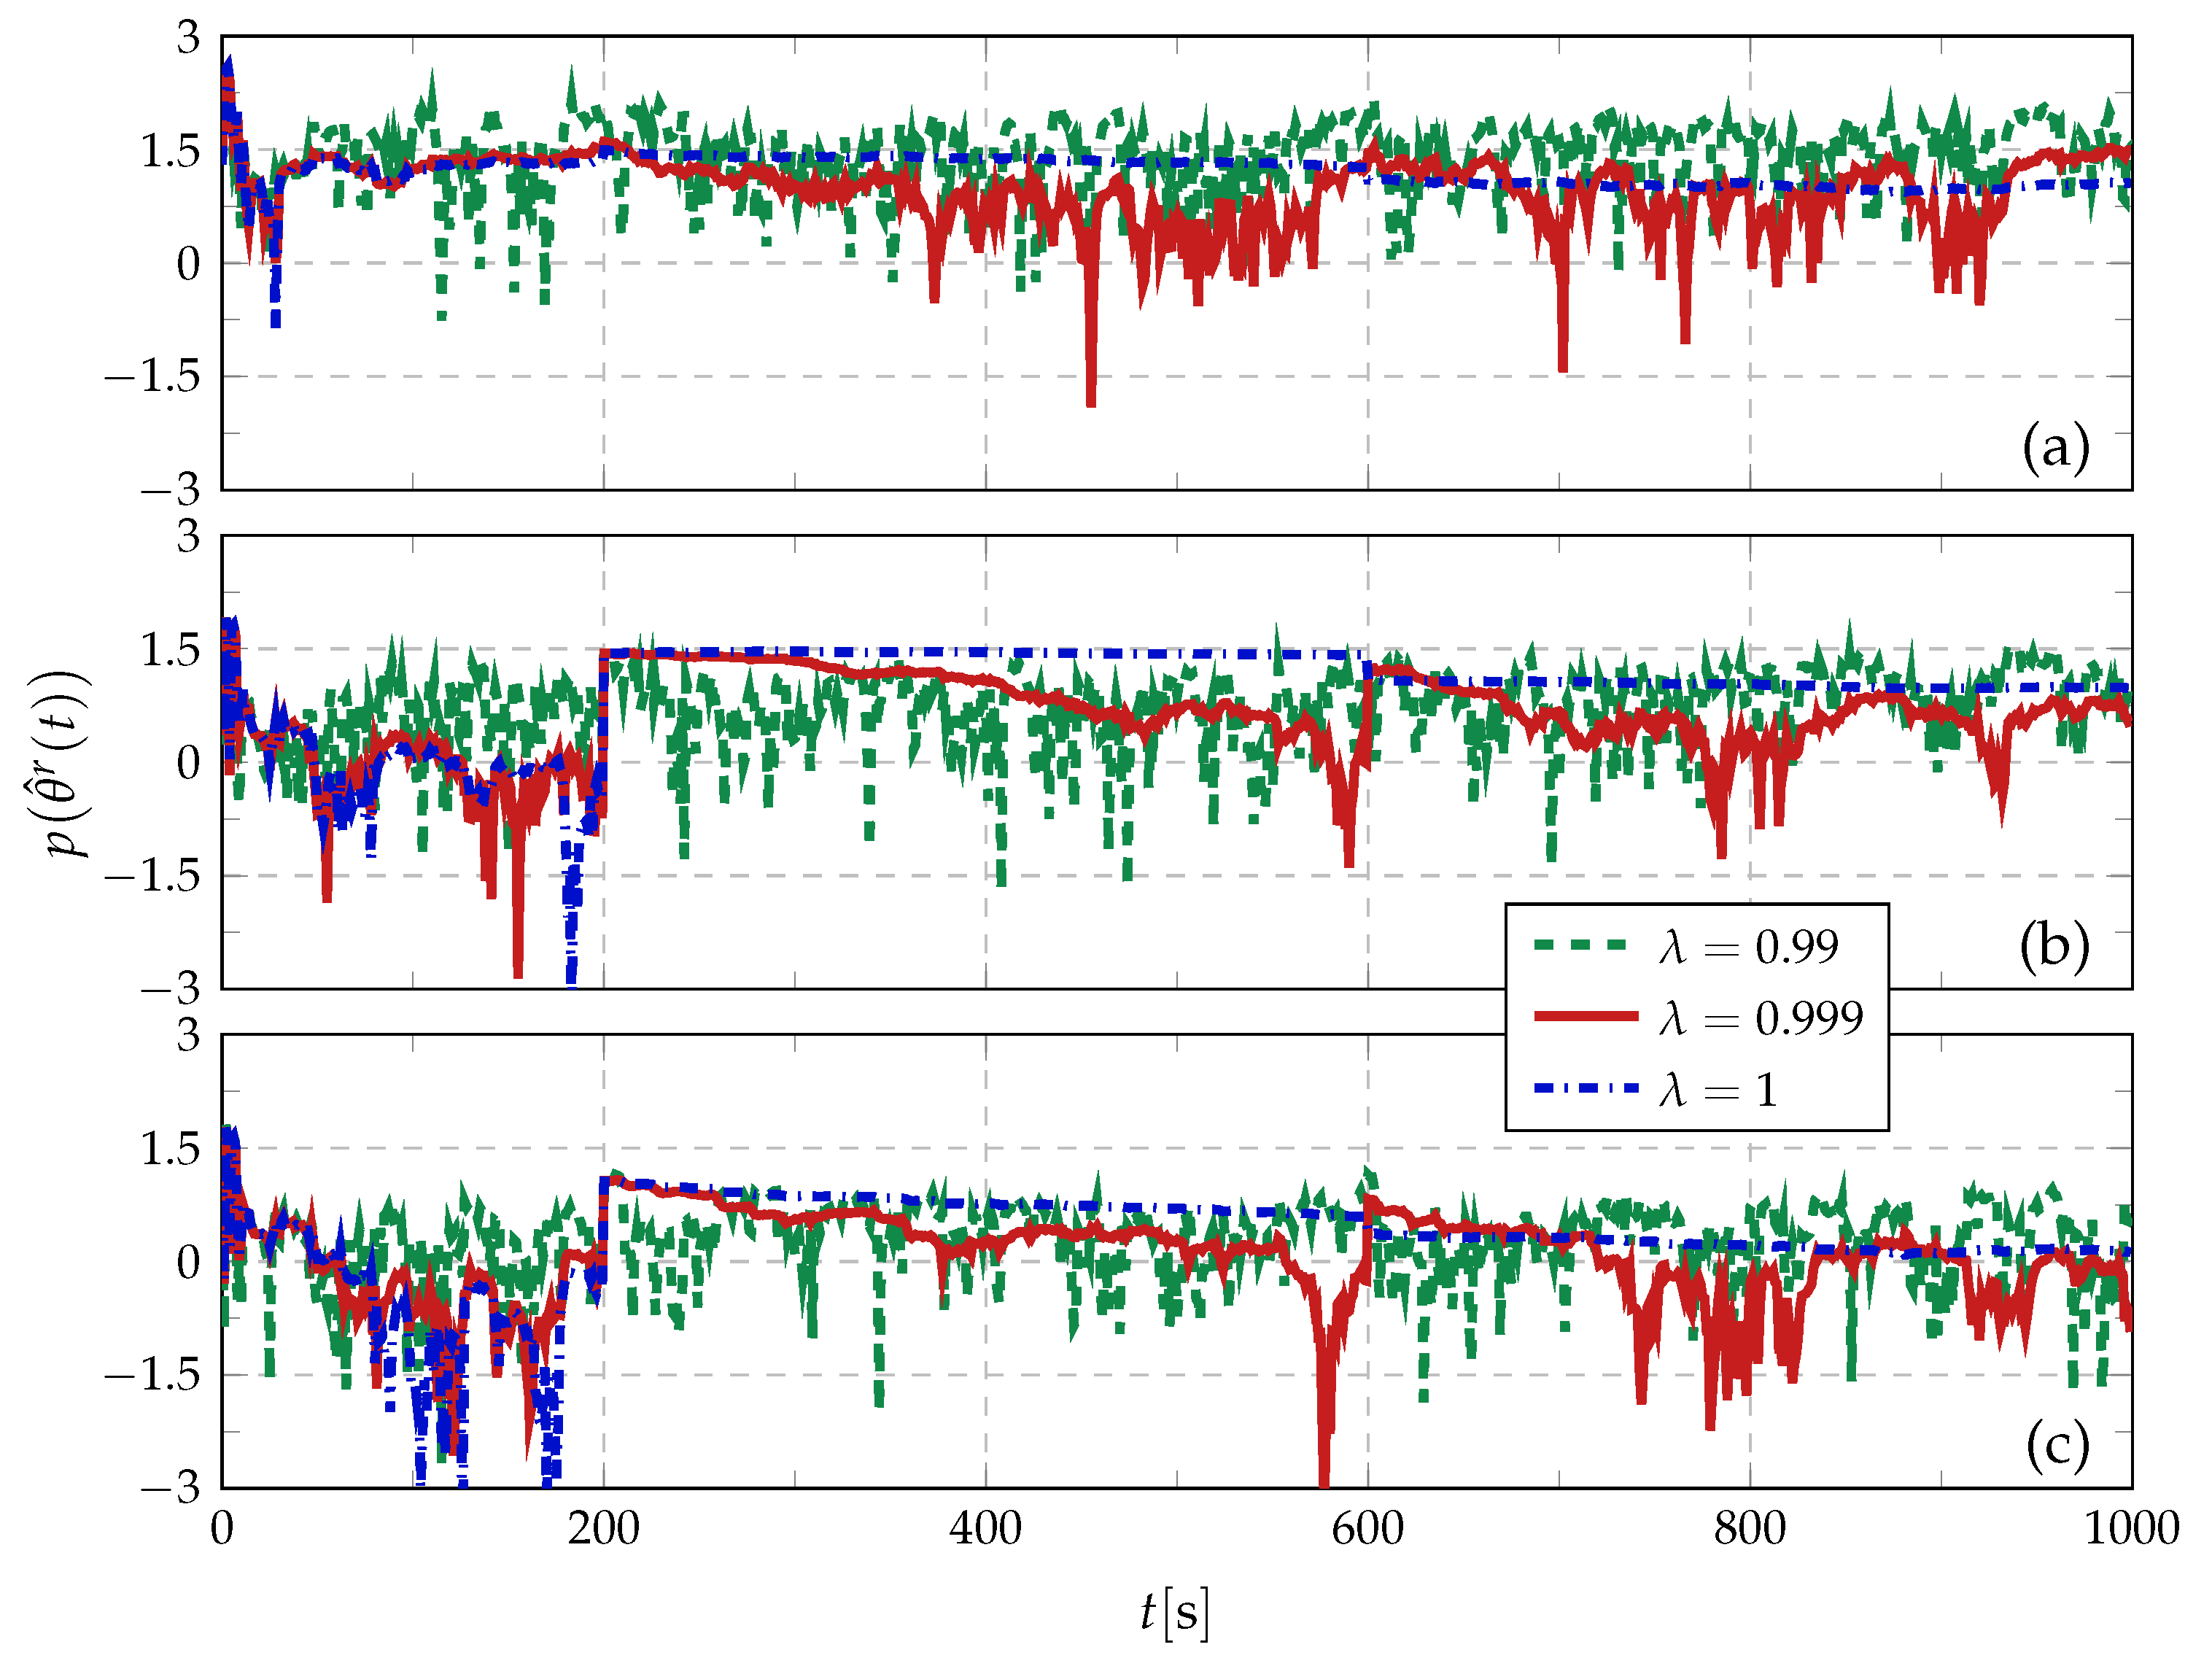
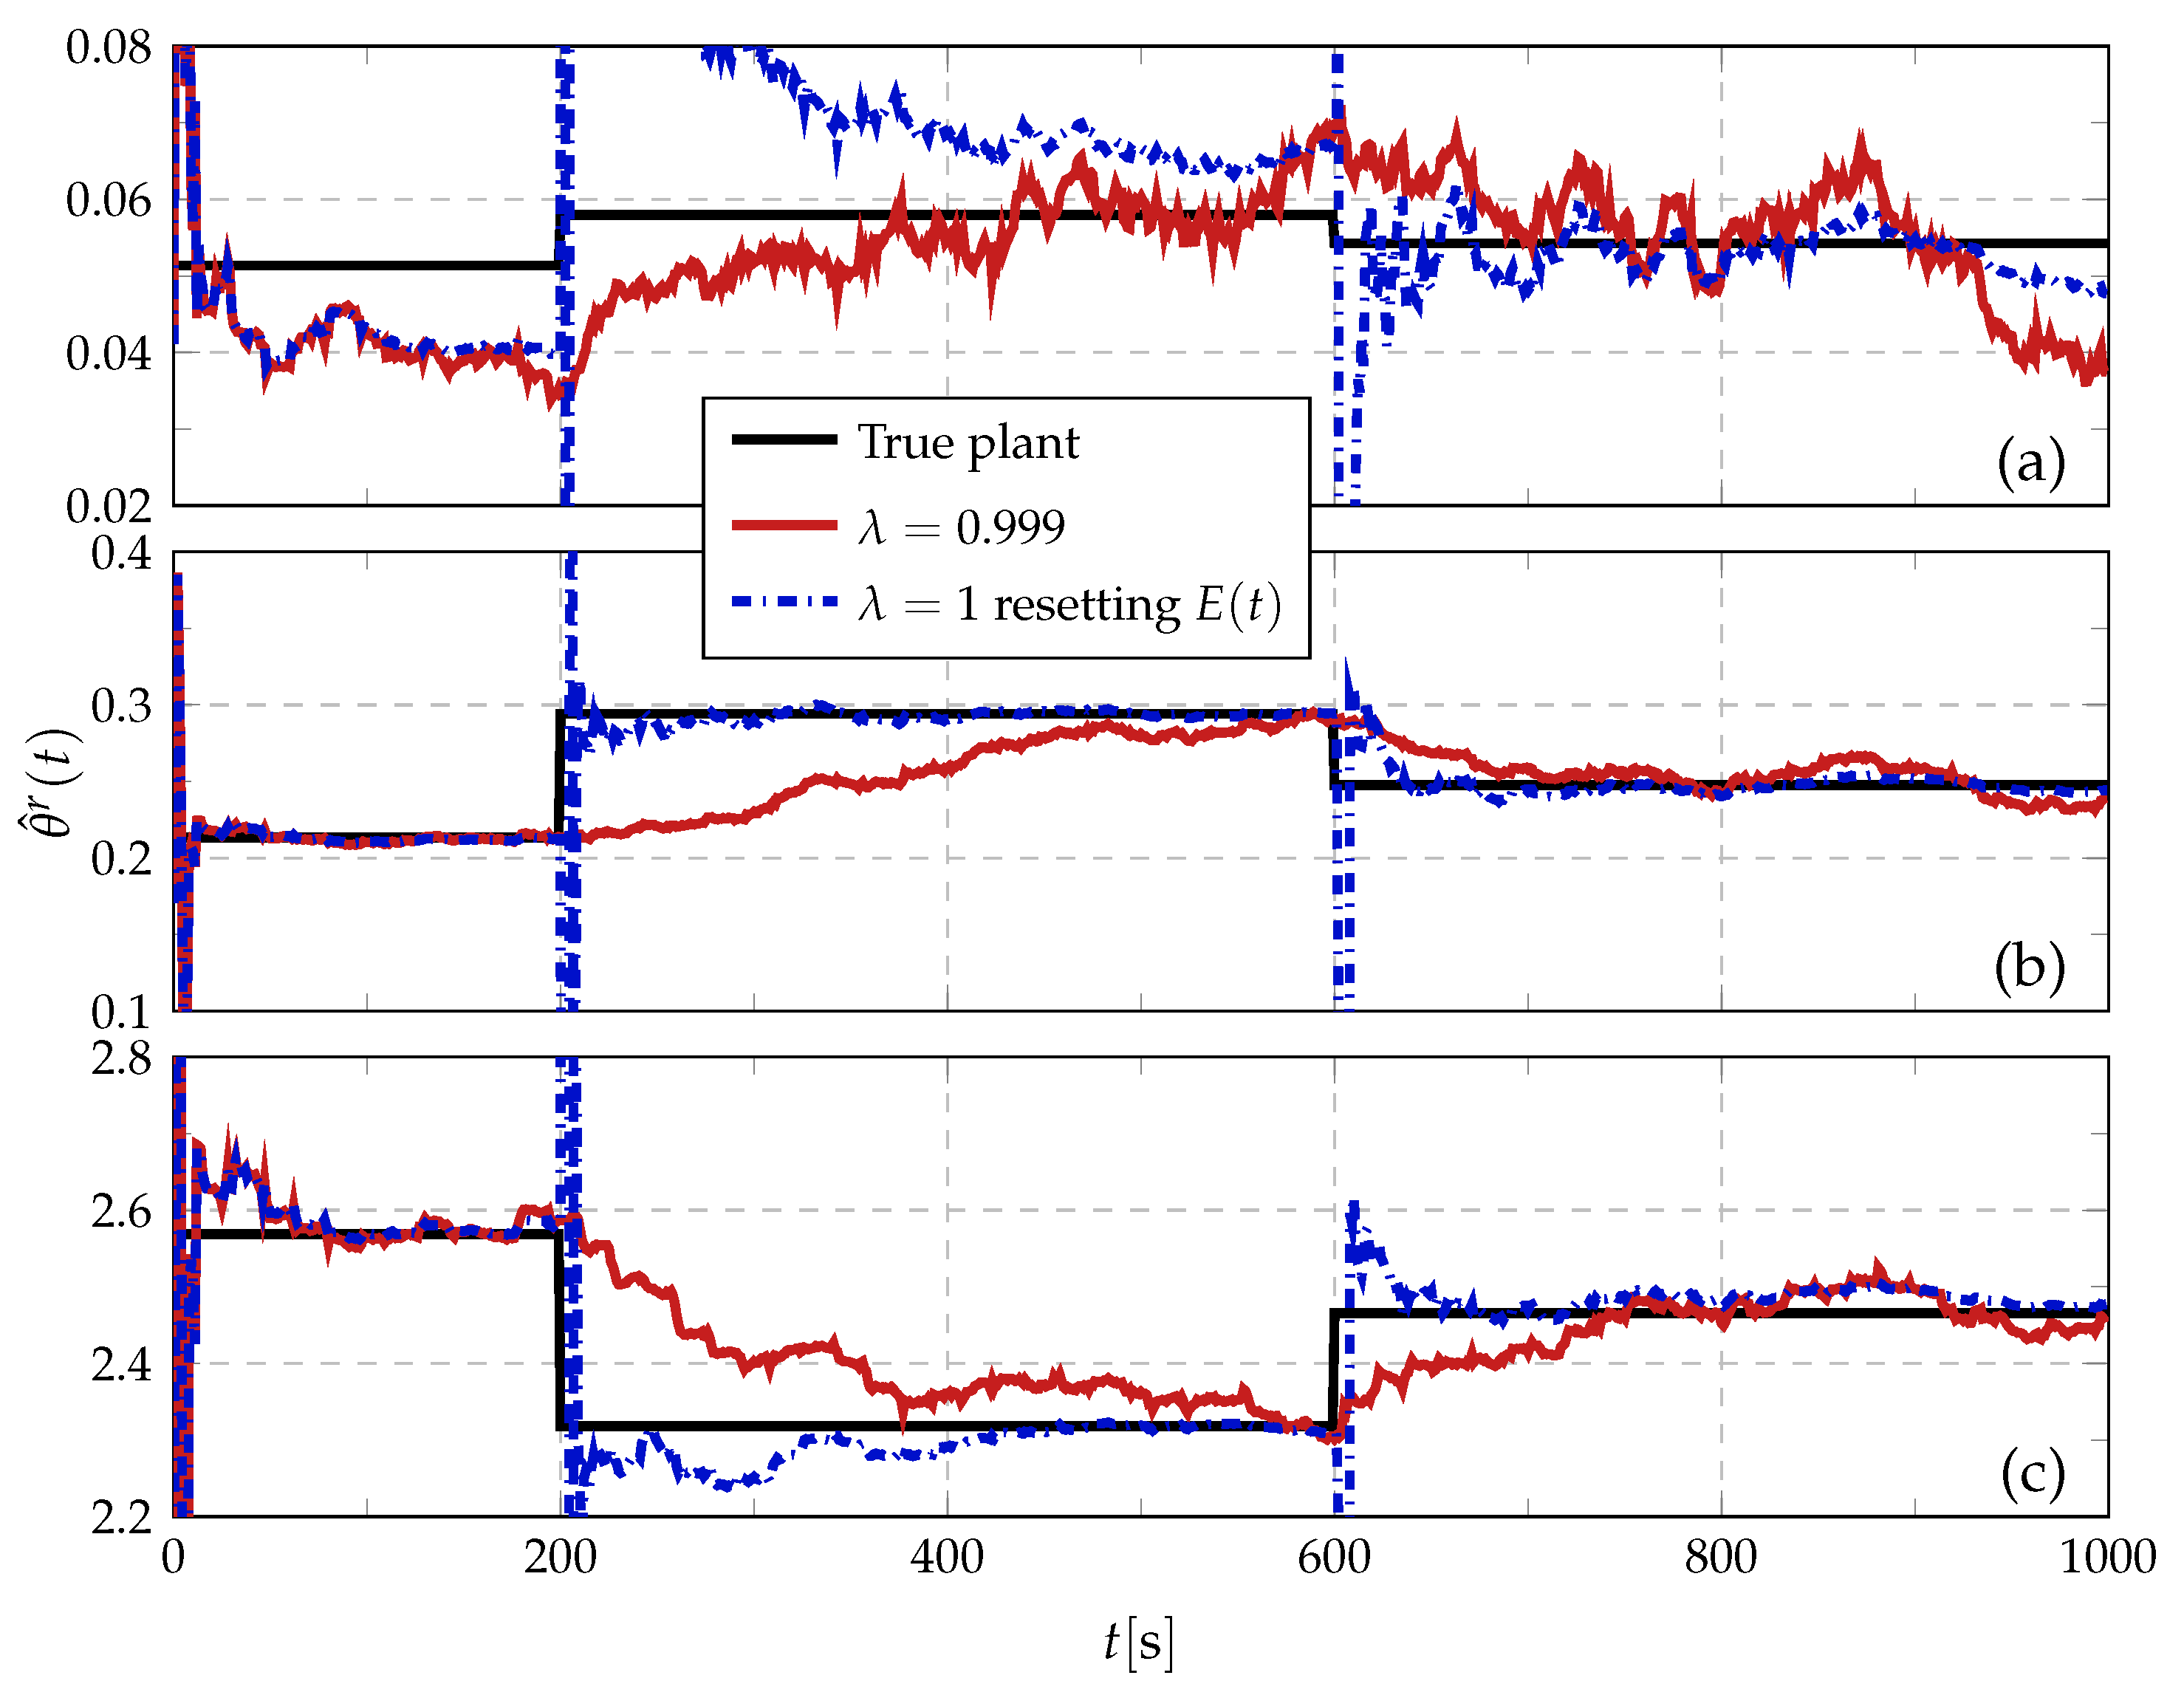
5.4. Closed-Loop Results
6. Conclusions
Author Contributions
Funding
Institutional Review Board Statement
Informed Consent Statement
Data Availability Statement
Conflicts of Interest
References
- Ma, A.; Li, D.; Xi, Y. Robust tube-based distributed MPC for PWA systems. IET Control Theory Appl. 2023, 17, 2205–2214. [Google Scholar]
- Vicente, B.A.H.; Trodden, P.A. Switching Tube-Based MPC: Characterization of Minimum Dwell-Time for Feasible and Robustly Stable Switching. IEEE Trans. Autom. Control 2019, 64, 4345–4352. [Google Scholar]
- Lin, M.; Ning, Z.; Li, B.; Zhang, K. Adaptive dual model predictive control for linear systems with parametric uncertainties. IET Control Theory Appl. 2022, 16, 1075–1085. [Google Scholar] [CrossRef] [Scilit]
- Zeng, Z.; Wang, H.; Shan, Y. Data-Driven Koopman Operator-Based Model Predictive Control with Adaptive Dictionary Learning for Nonlinear Industrial Process Optimization. Mathematics 2026, 14, 1320. [Google Scholar] [CrossRef] [Scilit]
- Gulewicz, D.; Inyang-Udoh, U.; Bird, T.; Jain, N. Nonlinear Model Predictive Control of a Hybrid Thermal Management System. IEEE Trans. Control Syst. Technol. 2025, 34, 892–905. [Google Scholar] [CrossRef] [Scilit]
- Rawlings, J.B.; Mayne, D.Q.; Diehl, M.M. Model Predictive Control: Theory, Computation and Design, paperback ed.; Nob Hill Publishing: Madison, WI, USA, 2020. [Google Scholar]
- Gao, Y.; Gray, A.; Tseng, H.E.; Borrelli, F. A tube-based robust nonlinear predictive control approach to semiautonomous ground vehicles. Veh. Syst. Dyn. 2014, 52, 802–823. [Google Scholar] [CrossRef] [Scilit]
- Trodden, P. A One-Step Approach to Computing a Polytopic Robust Positively Invariant Set. IEEE Trans. Autom. Control 2016, 61, 4100–4105. [Google Scholar] [CrossRef] [Scilit]
- Adetola, V.; DeHaan, D.; Guay, M. Adaptive model predictive control for constrained nonlinear systems. Syst. Control Lett. 2009, 58, 320–326. [Google Scholar] [CrossRef] [Scilit]
- Gonçalves, G.A.; Guay, M. Robust discrete-time set-based adaptive predictive control for nonlinear systems. J. Process Control 2016, 39, 111–122. [Google Scholar] [CrossRef] [Scilit]
- Lorenzen, M.; Cannon, M.; Allgöwer, F. Robust MPC with recursive model update. Automatica 2019, 103, 461–471. [Google Scholar] [CrossRef] [Scilit]
- Anderson, A.; González, A.; Ferramosca, A.; D’Jorge, A.; Kofman, E. Robust MPC suitable for closed-loop re-identification, based on probabilistic invariant sets. Syst. Control Lett. 2018, 118, 84–93. [Google Scholar]
- Heirung, T.A.N.; Ydstie, B.E.; Foss, B. Dual adaptive model predictive control. Automatica 2017, 80, 340–348. [Google Scholar] [CrossRef] [Scilit]
- Larsson, C.A.; Rojas, C.R.; Bombois, X.; Hjalmarsson, H. Experimental evaluation of model predictive control with excitation (MPC-X) on an industrial depropanizer. J. Process Control 2015, 31, 1–16. [Google Scholar] [CrossRef] [Scilit]
- Green, M.; Moore, J.B. Persistence of excitation in linear systems. Syst. Control Lett. 1986, 7, 351–360. [Google Scholar] [CrossRef] [Scilit]
- Ljung, L. System Identification Theory for the User, 2nd ed.; Prentice Hall: Upper Saddle River, NJ, USA, 1998; p. 640. [Google Scholar]
- Genceli, H.; Nikolaou, M. New approach to constrained predictive control with simultaneous model identification. AIChE J. 1996, 42, 2857–2868. [Google Scholar] [CrossRef] [Scilit]
- Lu, X.; Cannon, M.; Koksal-Rivet, D. Robust adaptive model predictive control: Performance and parameter estimation. Int. J. Robust Nonlinear Control 2021, 31, 8703–8724. [Google Scholar]
- Lu, X.; Cannon, M. Robust adaptive model predictive control with persistent excitation conditions. Automatica 2023, 152, 110959. [Google Scholar] [CrossRef] [Scilit]
- Hernandez Vicente, B.A. Eigenvalue Characterization of Persistence of Excitation for Convex Adaptive Predictive Control. Int. J. Adapt. Control Signal Process. 2026, 1–11. [Google Scholar]
- Vicente, B.A.H.; Trodden, P.A. Stabilizing predictive control with persistence of excitation for constrained linear systems. Syst. Control Lett. 2019, 126, 58–66. [Google Scholar] [CrossRef] [Scilit]
- Zhu, Y.; Yan, W.; Zhu, Y. MPC closed-loop identification without excitation. J. Process Control 2021, 106, 122–129. [Google Scholar] [CrossRef] [Scilit]
- Soderstrom, T.; Ljung, L.; Gustavsson, I. Identifiability conditions for linear multivariable systems operating under feedback. IEEE Trans. Autom. Control 1976, 21, 837–840. [Google Scholar] [CrossRef]
- Shorten, R.; Wirth, F.; Mason, O.; Wulff, K.; King, C. Stability Criteria for Switched and Hybrid Systems. SIAM Rev. 2007, 49, 545–592. [Google Scholar] [CrossRef] [Scilit]
- Ong, C.J.; Wang, Z.; Dehghan, M. Model Predictive Control for Switching Systems With Dwell-Time Restriction. IEEE Trans. Autom. Control 2016, 61, 4189–4195. [Google Scholar] [CrossRef] [Scilit]
- Dehghan, M.; Ong, C.J. Discrete-time switching linear system with constraints: Characterization and computation of invariant sets under dwell-time consideration. Automatica 2012, 48, 964–969. [Google Scholar] [CrossRef] [Scilit]
- Bridgeman, L.J.; Danielson, C.; Di Cairano, S. Stability and feasibility of MPC for switched linear systems with dwell-time constraints. In Proceedings of the 2016 American Control Conference (ACC), Boston, MA, USA, 6–8 July 2016; pp. 2681–2686. [Google Scholar]
- Zhang, L.; Zhuang, S.; Braatz, R.D. Switched model predictive control of switched linear systems: Feasibility, stability and robustness. Automatica 2016, 67, 8–21. [Google Scholar] [CrossRef] [Scilit]
- Ljung, L.; Gustavsson, I.; Soderstrom, T. Identification of linear, multivariable systems operating under linear feedback control. IEEE Trans. Autom. Control 1974, 19, 836–840. [Google Scholar] [CrossRef]
- Mayne, D.Q.; Seron, M.M.; Raković, S.V. Robust model predictive control of constrained linear systems with bounded disturbances. Automatica 2005, 41, 219–224. [Google Scholar] [CrossRef] [Scilit]
- Hansen, P.C. Rank-Deficient and Discrete Ill-Posed Problems: Numerical Aspects of Linear Inversion; Mathematical Modeling and Computation; Society for Industrial and Applied Mathematics (SIAM): Philadelphia, PA, USA, 1998; Volume 4. [Google Scholar]
- Kolmanovsky, I.; Gilbert, E.G. Theory and computation of disturbance invariant sets for discrete-time linear systems. Math. Probl. Eng. 1998, 4, 934097. [Google Scholar] [CrossRef] [Scilit]

 ,
 and
 .


| Mass [kg] | Spring Stiffness | Damper Coefficient |
|---|---|---|
| 30 |
| Parameter | Controller 1 | Controller 2 | Controller 3 |
|---|---|---|---|
| Mass | 2 | ||
| Stiffness | 8 | 10 | 9 |
| Damping | 30 | 30 | 30 |
| 10 | 10 | 10 | |
| 3 | 3 | 3 | |
| Closed-loop poles | |||
| minimal admissible RPI set [32] | |||
| maximal admissible PI set [32] | |||
| To | ||||
|---|---|---|---|---|
| 1 | 2 | 3 | ||
| From | 1 | - | 76 | 33 |
| 2 | 52 | - | 53 | |
| 3 | 32 | 69 | - | |
| Parameter | Mode 1 | Mode 2 | Mode 3 |
|---|---|---|---|
| Mass | 2 | ||
| Stiffness | 10 | ||
| Damping | 30 | 30 | 30 |
| Time span [s] | [0–200] | [200–600] | [600–1000] |
| 2000 steps |
| (No Resetting) | (Resetting) | |
|---|---|---|
| Without switching | ||
| With switching |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Sepulveda Carrasco, I.A.; Hernandez Vicente, B.A. Switching Adaptive Model Predictive Control for Perturbed Linear Time-Varying Systems. Mathematics 2026, 14, 2281. https://doi.org/10.3390/math14132281
Sepulveda Carrasco IA, Hernandez Vicente BA. Switching Adaptive Model Predictive Control for Perturbed Linear Time-Varying Systems. Mathematics. 2026; 14(13):2281. https://doi.org/10.3390/math14132281
Chicago/Turabian StyleSepulveda Carrasco, Ignacio Alejandro, and Bernardo A. Hernandez Vicente. 2026. "Switching Adaptive Model Predictive Control for Perturbed Linear Time-Varying Systems" Mathematics 14, no. 13: 2281. https://doi.org/10.3390/math14132281
APA StyleSepulveda Carrasco, I. A., & Hernandez Vicente, B. A. (2026). Switching Adaptive Model Predictive Control for Perturbed Linear Time-Varying Systems. Mathematics, 14(13), 2281. https://doi.org/10.3390/math14132281