


Abstract
Robotic blimps have been recently employed for the purpose of education and research. Both modeling and simulation for robotic blimp motions are significantly important due to uncontrollable movements. This paper presents the coupled rolling behaviors of robotic blimps. When horizontal and vertical motions are combined for vehicle maneuvering, rolling motion can be substantially increased. We propose an analytic solution of a simplified model that represents coupled rolling motion in order to analyze such instability. Furthermore, we prove that rolling motions under unknown disturbances are ultimately bounded from Lyapunov analysis. The proposed scheme is verified by simulation study.
MSC:
37N35
1. Introduction
Robotic blimps have been researched in various fields over the past two decades. Light field mapping [1], localization [2], and simultaneous localization and mapping [3] are researched for robotics and autonomy. In addition, robotic blimps are utilized for entertainment [4] and underwater vehicle emulation [5].
Robotic blimps are generally designed for a bottom-heavy configuration. The blimp envelope formed by soft materials such as mylar films has helium gas, which is lighter than air. The shape of the envelope can be varied; for example, cigar [6], cylinder [7], saucer [8], and sphere [9]. In their envelopes, there are two types of lifting forces: static and dynamic. Buoyancy force is static force computed by the volume of the envelop and gas density. Aerodynamic lift force is dynamic force calculated by the shape of the envelope, dynamic pressure, and air density. The gondola installed in the bottom of the envelope is much heavier than the blimp envelop in that the gondola is composed of motors and propellers, a microprocessor board, communication modules, and sensor packages. Typically, cylinder, saucer, and sphere shapes have no control fins, but their propellers are used for control forces and moments.
Robotic blimp motions are generated by six degree-of-freedom dynamics. Three translational motions of robotic blimps according to axes are defined as surge, sway, and heave motions, respectively. Three angular motions of robotic blimps according to axes are defined as rolling, pitching, and yawing motions, respectively. Blimp motion is affected by the number of rotors and their arrangement. For instance, reference [10] has six rotors that control the blimp motions. One pair of rotors are vertically installed in the gondola for heave motions. Two pairs of rotors are horizontally installed in the gondola for surge, sway, and yawing motions. Thus, pitching and rolling motions are not directly controlled in the sense that no control means exist, called an underactuated system. We address an underactuated system of a sphere-shape robotic blimp including a bottom heavy configuration. Especially, we analyze a combined motion composed of sway and heave movements in that blimp swarming and human–blimp interaction may lead to such complex blimp motions.
We propose a coupled rolling motion model that represents rolling behaviors when horizontal and vertical motions are combined. By analytically solving the proposed model, we find that rolling motion is increased according to frequency. Furthermore, the analytic solution is ultimately bounded in the sense of Lyapunov.
1.1. Related Work
Underactuated systems such as unmanned surface vehicles and robot manipulators are active in research. Underactuated systems have greater number of degree-of-freedom than the number of actuations. The three degree of freedom of unmanned surface vehicles in [11], represented by surge, sway, and yaw motions, are controlled by two actuations. In addition, a pendubot with two degree-of-freedom is controlled by one actuation in [12]. Our research does not deal with a controller design for underactuated systems, but derives an analytic solution in order to analyze an underactuated motion.
For indoor autonomous blimps, previous study in [10] describes a controller design for coupled pitching motion in a bottom-heavy configuration. When a blimp starts to move forward from being at rest while assuming zero roll angle, pitching motion of the blimp is abruptly induced, called coupled pitching motion. However, our research is different from coupled pitching motion in that combination of upward and sideway motions induces roll angles of the blimp, called coupled rolling motion. Moreover, our sideway motion is bi-directional, which is different from one-directional forward movement of previous study. Our research is compatible to previous study in the sense that upward and sideway control loop designs can be feasible to reduce coupled rolling motion, which is not considered by previous study.
Analytically solving underactuated systems is difficult in that the solutions of nonlinear time-varying differential equations are not known, generally. In [13], the dynamics of Hopfiled neural network, which is a class of nonautonomous system with periodic coefficients and time delays, converges to a -anti-periodic solution. In [14], a maximal solution of a nonautonomous system that represents brain metabolites variations is proposed. In [15], a global mild solution of a nonautonomous abstract evolution equation is proposed. Even if some underactuated systems described by nonlinear autonomous systems containing equilibrium points are analytically solved, nonlinear nonautonomous systems without equilibrium points have not yet been solved.
1.2. Major Contribution
We propose an uncontrolled motion model described by nonlinear nonautonomous systems without equilibrium points by merging two orthogonal motions composed of heave and sway motions. When sway and heave motions are generated by vertical and horizontal propellers, respectively, rolling motion is produced because of rolling moments induced by combined motion and a distance between center of gravity and the center of thrust as well as buoyancy force and a distance between center of gravity and the center of buoyancy. The uncontrolled motion model is obtained from the assumption of small angles and the absence of aerodynamic damping and unknown disturbance. We analytically derive a general solution by summing homogenous and particular solutions of the proposed model. In addition, we show that rolling motion is ultimately bounded in the sense of Lyapunov.
1.3. Organization
This paper consists of following sections: in Section 2, we describe problem setup. In Section 3 and Section 4, we present analytic solutions and ultimate boundedness of the proposed model. In Section 5, we show mathematical simulation to verify the results of the third and fourth sections. In Section 6, we describe conclusion and future work.
2. Problem Setup
We describe an uncontrollable model of a sphere-shape robotic blimp. Let be a body axis of the blimp. Let , , be roll, pitch, yaw angles of Euler angle, respectively. Let p, q, r be roll, pitch, yaw angular velocities, respectively. Let , , , , , are the moment of inertia of the blimp as shown in [8]. There are three points acting from external forces: that is, the center of gravity (CG), the center of buoyancy (CB), and the center of thrust force (CT). Since gravity force W, buoyancy force B, and thrust force T are defined in three dimensional space, all the three forces are projected in as , , and for the analysis of rolling motion, respectively.
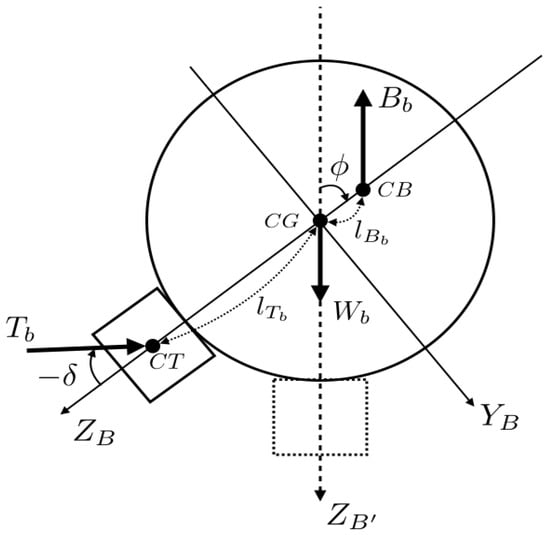
Figure 1 shows that roll angle is generated by the projected forces and and moment arms and with respect to CG. The positive direction of the roll angle is clockwise because a right hand rule is applied with respect to perpendicular to plane . The direction of combined thrust forces is defined as . We model as a sinusoidal function depending on time represented by . Although is zero when heave motion occurs without sway motion, combination of two motions for vehicle maneuvering cause non-zero . Thus, we define and as the maximum value of and a frequency of the sinusoidal function, respectively. Aerodynamic rolling moment contains coefficient proportional to roll angular velocity p. Moreover, uncertain external disturbances cause an additional rolling moment. For example, unintended human touch and unknown wind are able to make rolling moments of the blimps.
Figure 1.
Induced rolling behaviors of a sphere-shape robotic blimp.
Let be an such disturbances bounded by . From rigid body dynamics, we have a uncontrollable model as follows:
where and represent perpendicular forces with respect to axis and moment arms with respect to CG, respectively. Because (1) has no control for rolling behavior, we call this model an uncontrollable model. We assume that , when the shape of the blimp is sphere. This assumption is valid in that all the three planes formed by , , and axes are symmetric. From (1), we have
We assume that roll angle and thrust direction angle are small, and is constant. Note that and because can be zero regulated in [10]. Then,
where , , and are constant. Equation (3) represents a coupled rolling motion model of the robotic blimp. Because is a sinusoidal function according to time t, the proposed model is an uncontrollable model represented by a nonlinear nonautonomous system without equilibrium points. Our goal is to derive an analytic solution of the uncontrollable model so that we will show the coupled rolling motion is significantly decreased according to frequency of the sinusoidal function. In the next section, we will describe the analytic solution of the uncontrollable model.
3. Analytic Solution of Uncontrollable Model
This section describes state–space representation of the uncontrollable model represented by (3) for deriving an analytic solution. Let be roll angle and roll angular velocity, respectively. Then,
Assumption 1.
Roll angle and roll angular velocity have zero initial values.
Remark 1.
When the blimp starts to move from the rest, coupled rolling motions are driven by the combination of heave and sway motions. Thus, we assume that initial states and are zeros.
Assumption 2.
Roll angle and roll angular velocity are small.
Remark 2.
Small coupled rolling motion is needed to control heave and sway motions of the blimp. We derive an analytic solution by assuming that both and are small.
Assumption 3.
The maximum thrust direction angle is 30 degs.
Remark 3.
The combination of heave and sway motions makes a diagonal movement of the blimp. Thrust direction angle 30 degs indicate that heave motion is around two times larger than sway motion for maneuvering the blimp.
Assumption 4.
Aerodynamic damping is ignored.
Remark 4.
We ignore aerodynamic damping to derive an analytic solution. Since aerodynamic damping has a negative sign that decreases roll angular velocity, the proposed analytic solution is a zero-damping solution. Aerodynamic damping is included in the analysis of boundedness.
Assumption 5.
Uncertain external disturbance is ignored.
Remark 5.
Uncertain disturbance is analyzed in the boundedness of the proposed model, together with aerodynamic damping.
To obtain a general solution of the coupled rolling motion model, we derive homogeneous and particular solutions as the following Lemmas.
Lemma 1.
By Assumptions 2, 4, 5, and letting , is the homogeneous solution of if for any constants and .
Proof.
From Assumptions 2, 4, 5, zero , and Equation (4), we obtain a second-order differential equation as follows:
Let be . When we plug into and double derivative of of (5), then (5) holds. Therefore, homogeneous solution of is □
Remark 6.
From the homogeneous solution, the buoyancy force and moments are critical due to the fact that natural frequency of the coupled rolling motion relies on . Note that and will be determined by the initial conditions in a next theorem.
Lemma 2.
By Assumptions 2–5, is the particular solution of if
Proof.
Let be . From Assumptions 2–5, and Equation (4), we derive the following equation:
Because is not a small angle, is approximated by double angle formula and the first-order approximation as follows:
When we plug into (7), we have
This results in
For any t, and
Therefore,
□
Remark 7.
When the frequency of the thrust direction equals the natural frequency of the coupled rolling motion model from the denominator of the particular solution, the particular solution goes to infinity. For decreasing roll angle of the particular solution, we need the frequency of the thrust direction larger than the natural frequency. Note that this approach to solving the particular solution can expand when . For example, if , we expand (8) and derive a solution with cosine law and small angle assumption.
Theorem 1.
By Assumptions 1–5, the general solution of is
Proof.
Let be . By Lemmas 1 and 2,
We have from Assumption 1. By using the initial conditions, we compute two unknowns and from (13). Then, and . Therefore,
□
Remark 8.
From Theorem 1, we need high frequency of thrust direction angle to decrease roll angle. This is because the magnitudes of both homogeneous solution and particular solution are decreased when is greater than . Note that roll angle is diverged when is equal to because of zero denominator. We call this a resonance condition.
In the next Corollary, we derive the lower bound of to meet a given roll angle.
Corollary 1.
Let be a small positive constant. Then,
such that if is greater than .
Proof.
By the triangle inequality,
because , , are positive, and is positive. Solving inequality of (16), we have
and
Since is negative, the upper bound of in (18) is always negative. Thus,
□
Remark 9.
Although we cannot achieve zero roll angle from the uncontrollable model, we find for small roll angle ϵ. Because is associated with vehicle maneuvering, we need to design high bandwidth of heave and sway motion controllers, which is far away from natural frequency induced by buoyancy moment.
4. Boundedness of Uncontrollable Model
This section presents boundedness of the uncontrollable model. The previous section shows an analytic solution of the model. The solution can be diverged due to ignoring the aerodynamic damping coefficient. Hence, we need to analyze how large the roll angle increase in the proposed model including the aerodynamic damping coefficient, represented by (4). In addition, we include uncertain disturbances in the uncontrollable model so that the analytic solution is robust. Let be an arbitrary positive constant such that .
Theorem 2.
The solutions of the proposed model are ultimately bounded, given constant β.
Proof.
Let V be a Lyapunov function candidate as follows.
Because is negative and both and are not zero, V is positive. The derivative of the Lyapunov function is derived by the following equation.
Since when , is negative definite. Therefore, the solutions of the proposed model is ultimately bounded. That is,
□
Remark 10.
Theorem 2 describes that roll angular velocity is bounded by , , , and β regardless of time. The bound of roll angular velocity becomes small when thrust moment and are small, bounded disturbance is small, and aerodynamic damping is large.
5. Simulation Results
We simulate an uncontrollable model that represents induced rolling behaviors of a robotic blimp. To verify the proposed analytic solutions, we simulate (7) generated by (4) by ignoring the aerodynamic damping coefficient and the bounded disturbance. For this simulation, the radius of a sphere, which is the envelope of the blimp, is considered as 2 m. We set the model parameters as follows: , , , , .
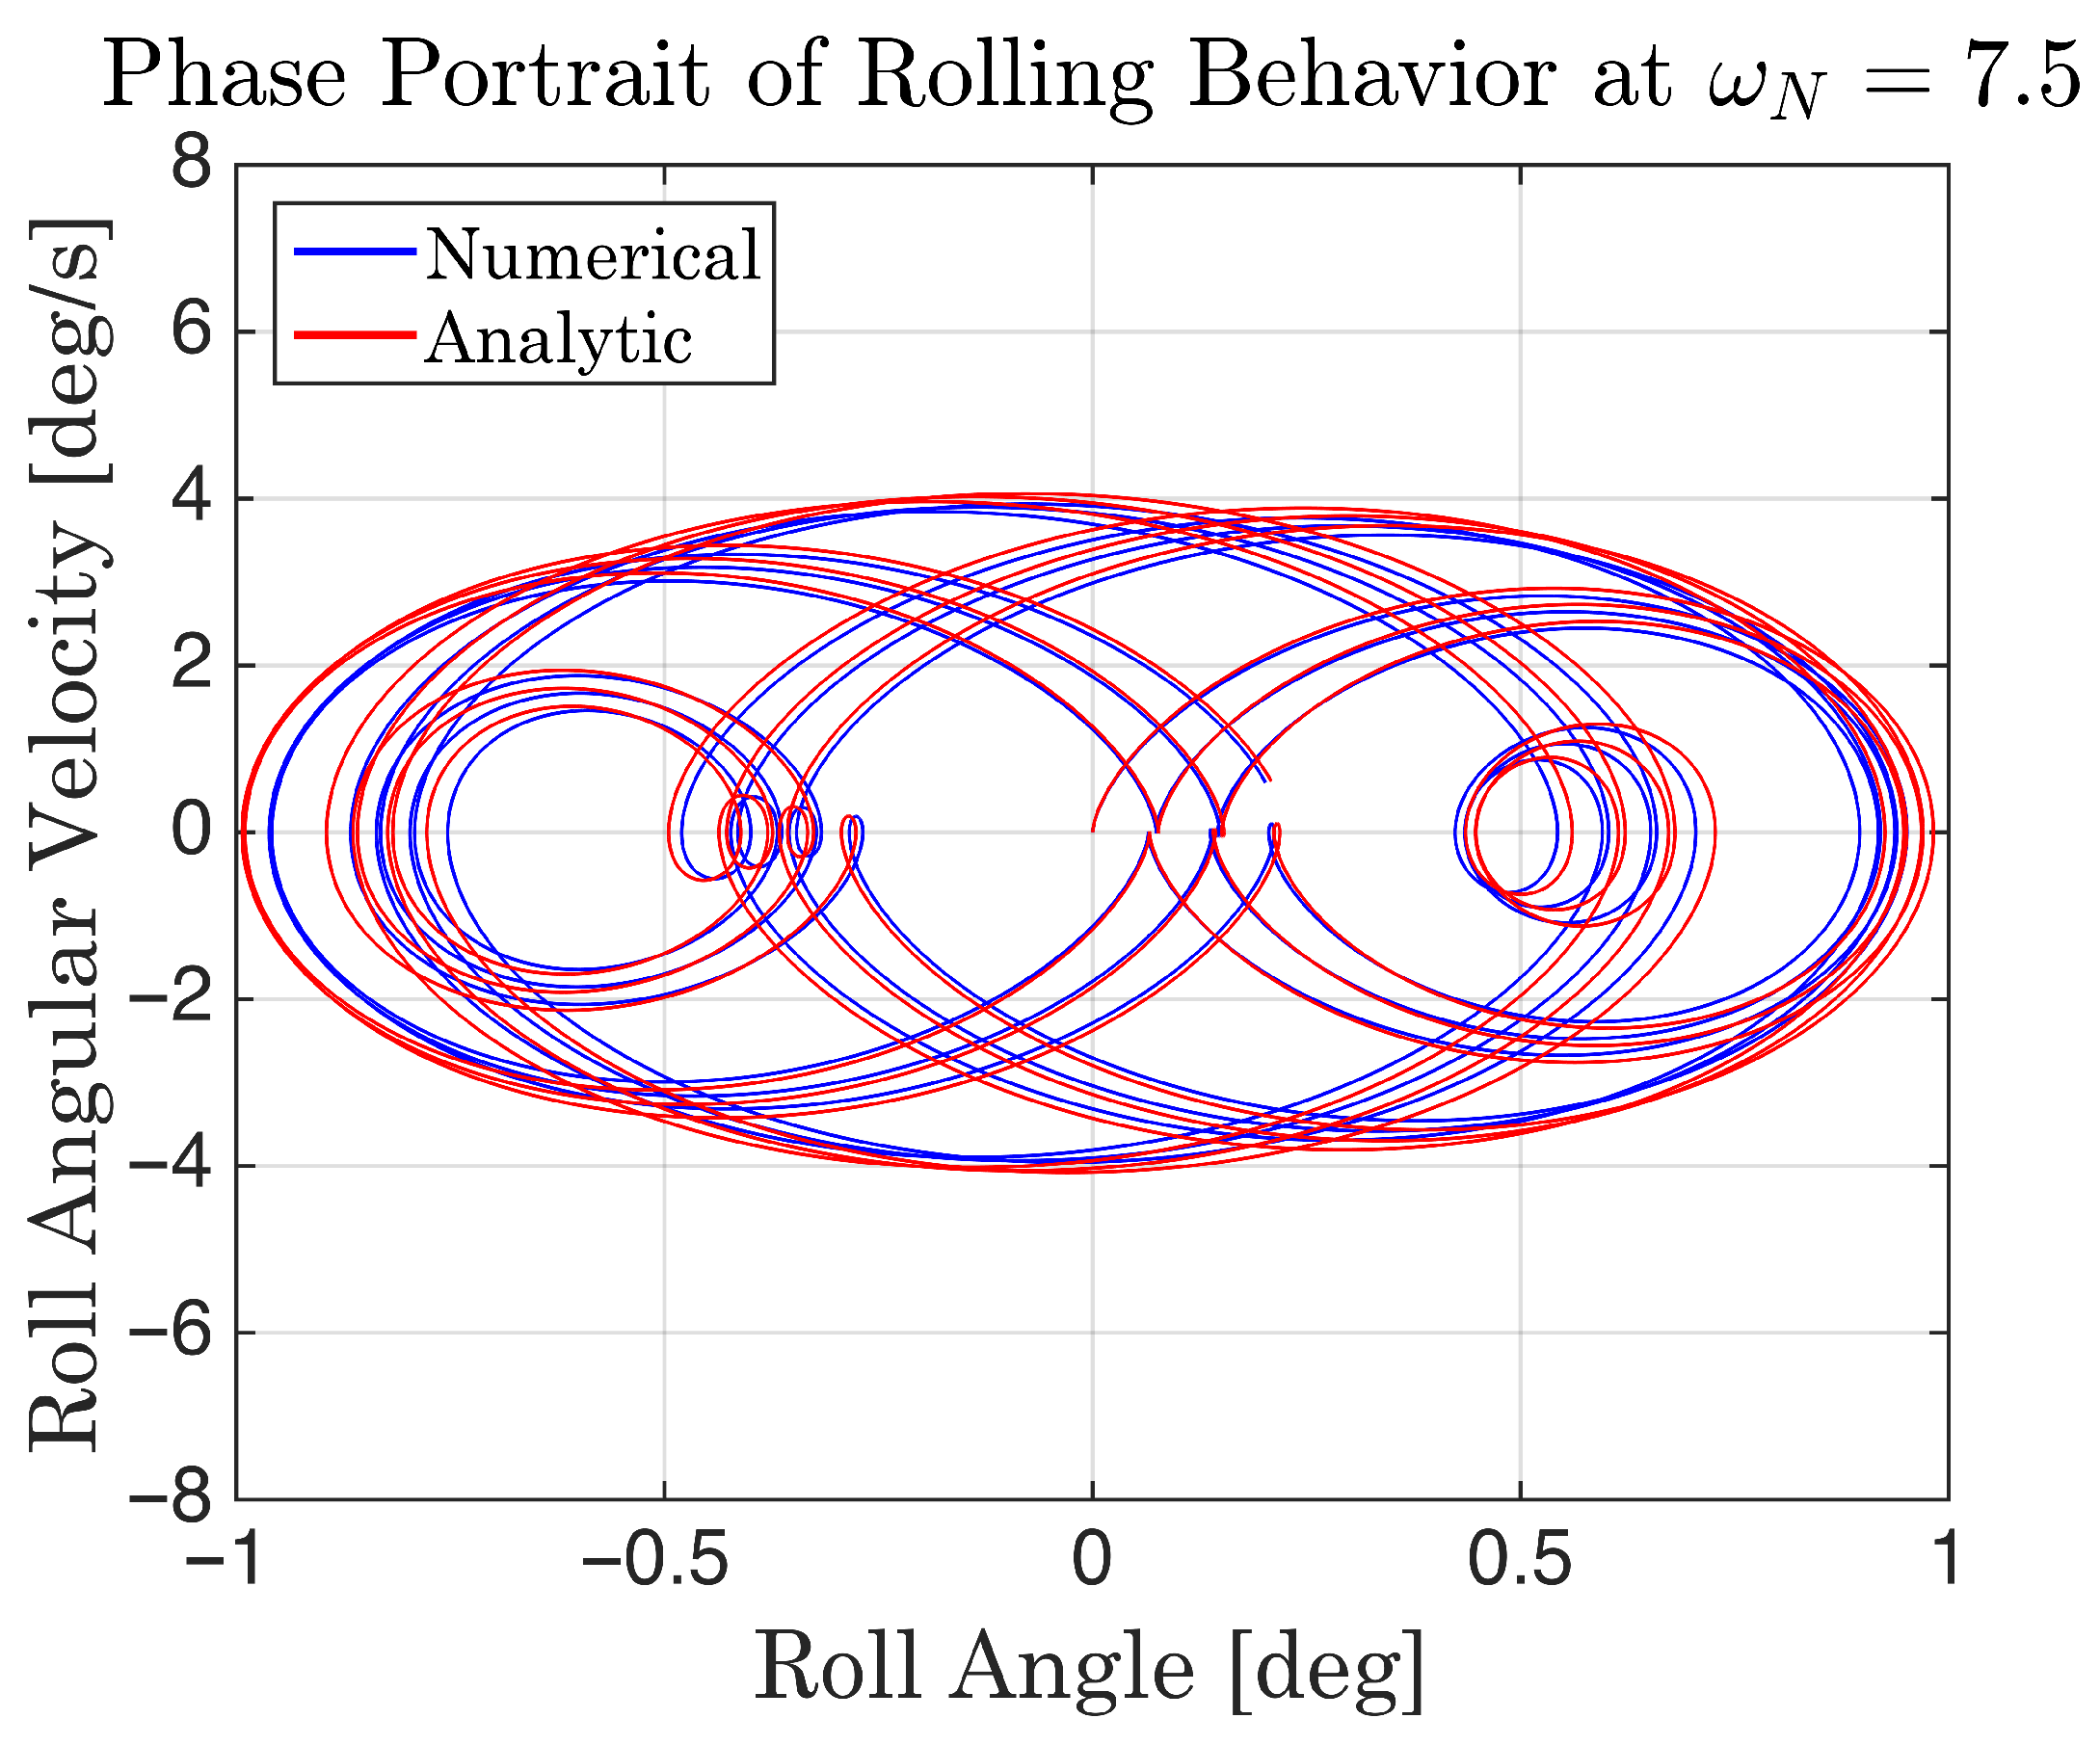
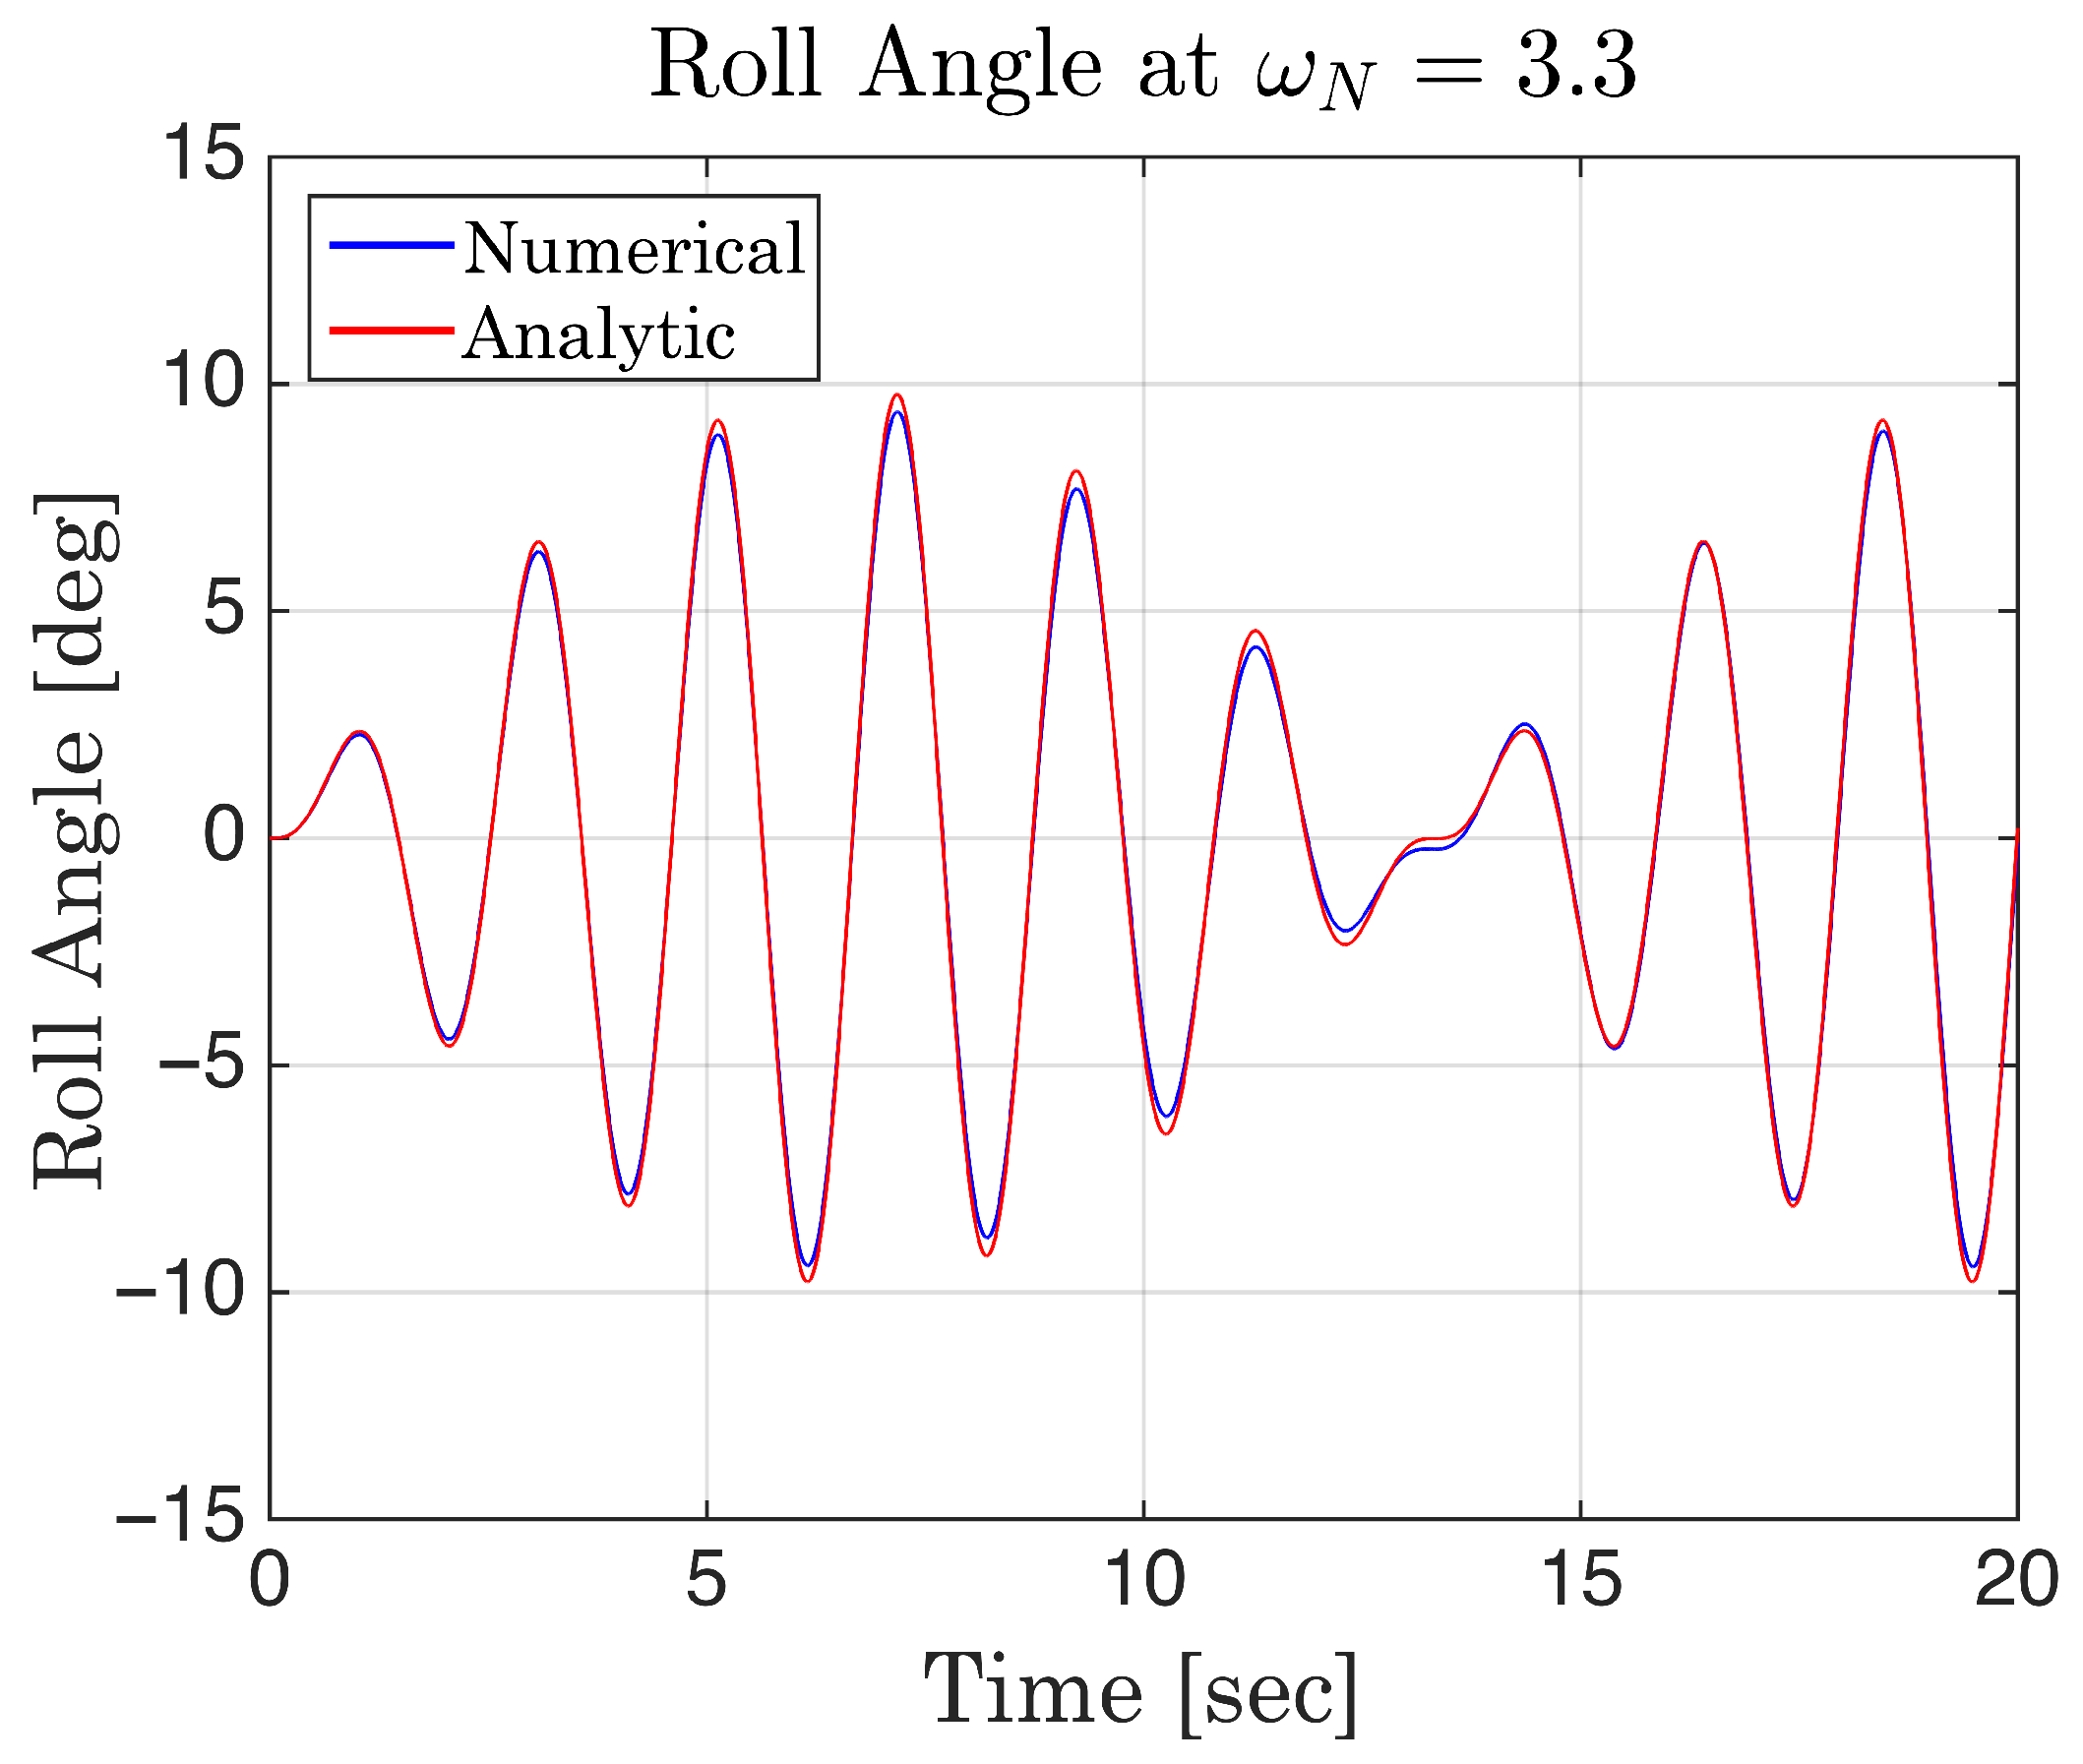
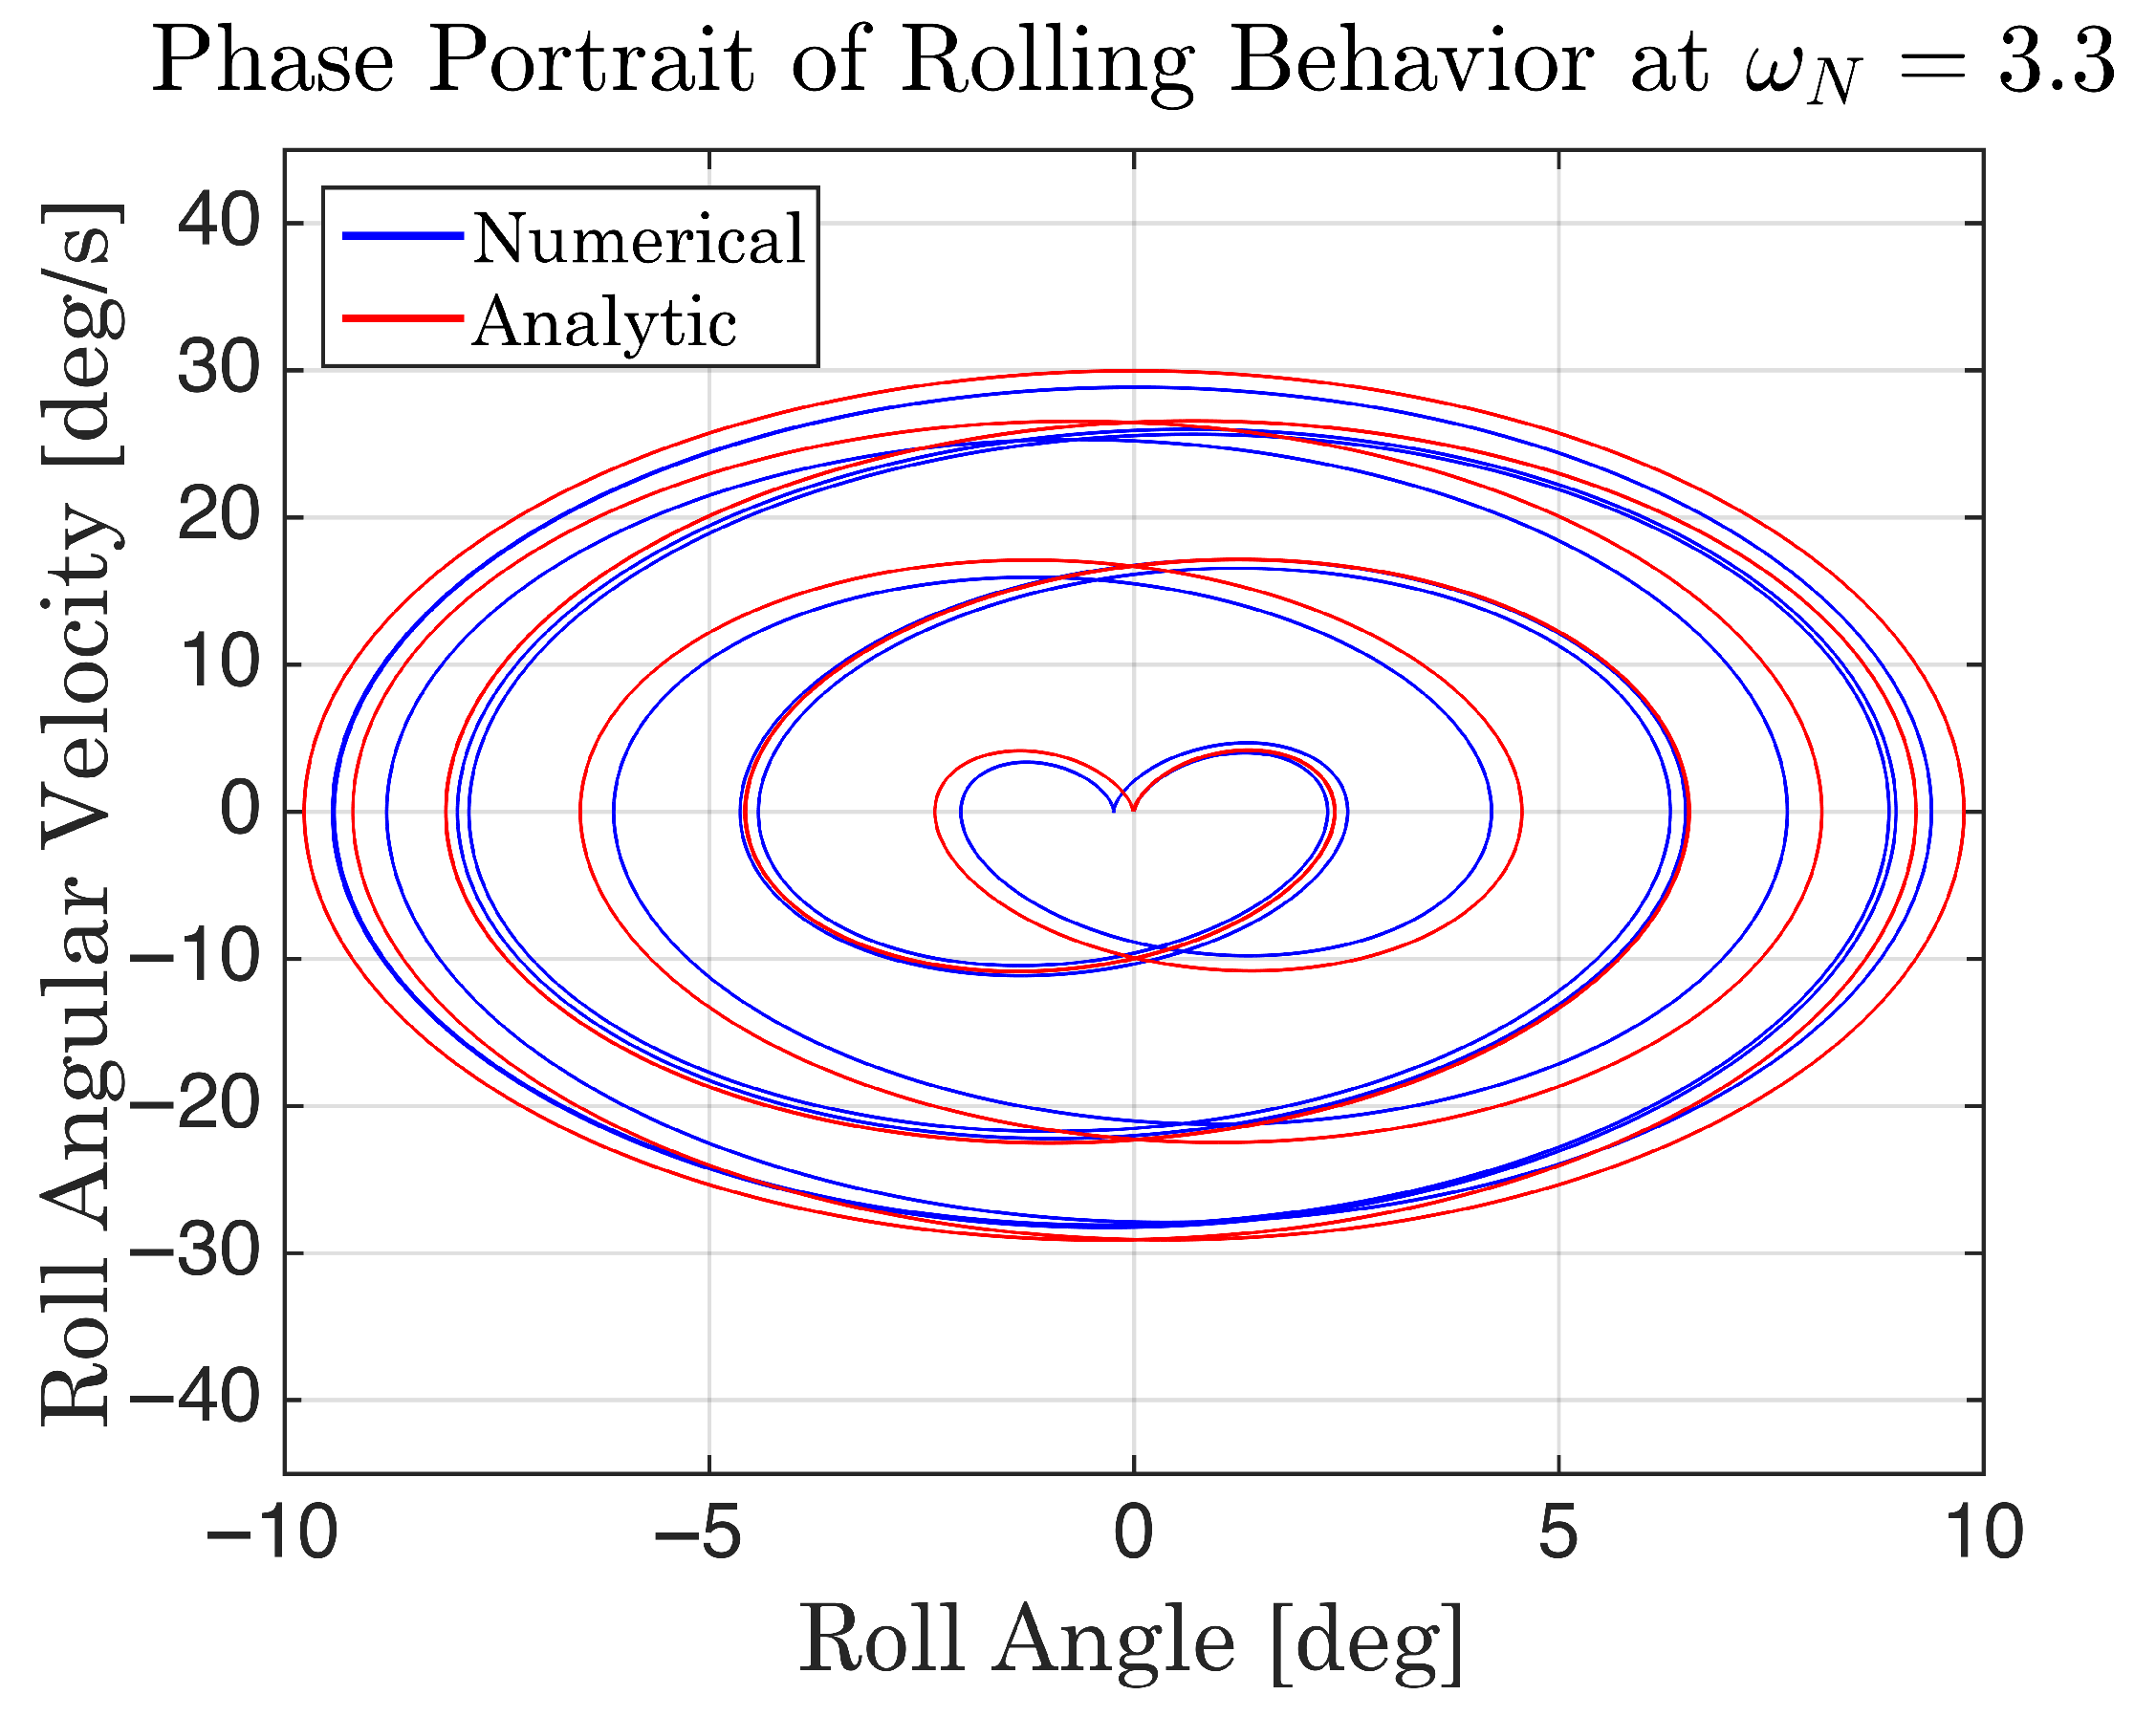
From Corollary 1, we compute for given . For example, when is 1 deg, the lower bound of is 7.5 rad/s from (15). In addition, when is 10 degs, the lower bound of is 3.3 rad/s. Since 3.3 rad/s is close to 2.8 rad/s that satisfies zero denominator of (14), roll angle can be increased. Thus, we choose two scenarios: is 7.5 rad/s and is 3.3 rad/s. The simulation results of each scenario are shown in the following figures.
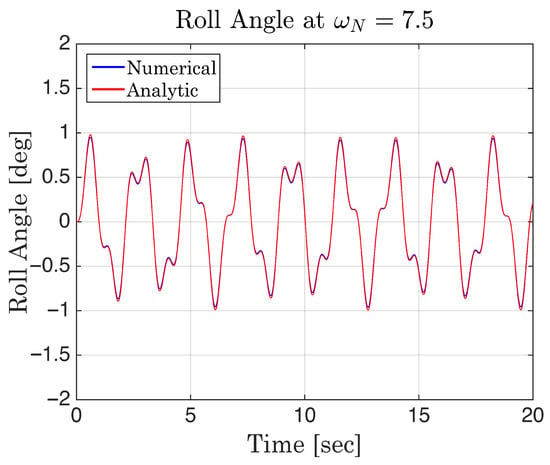
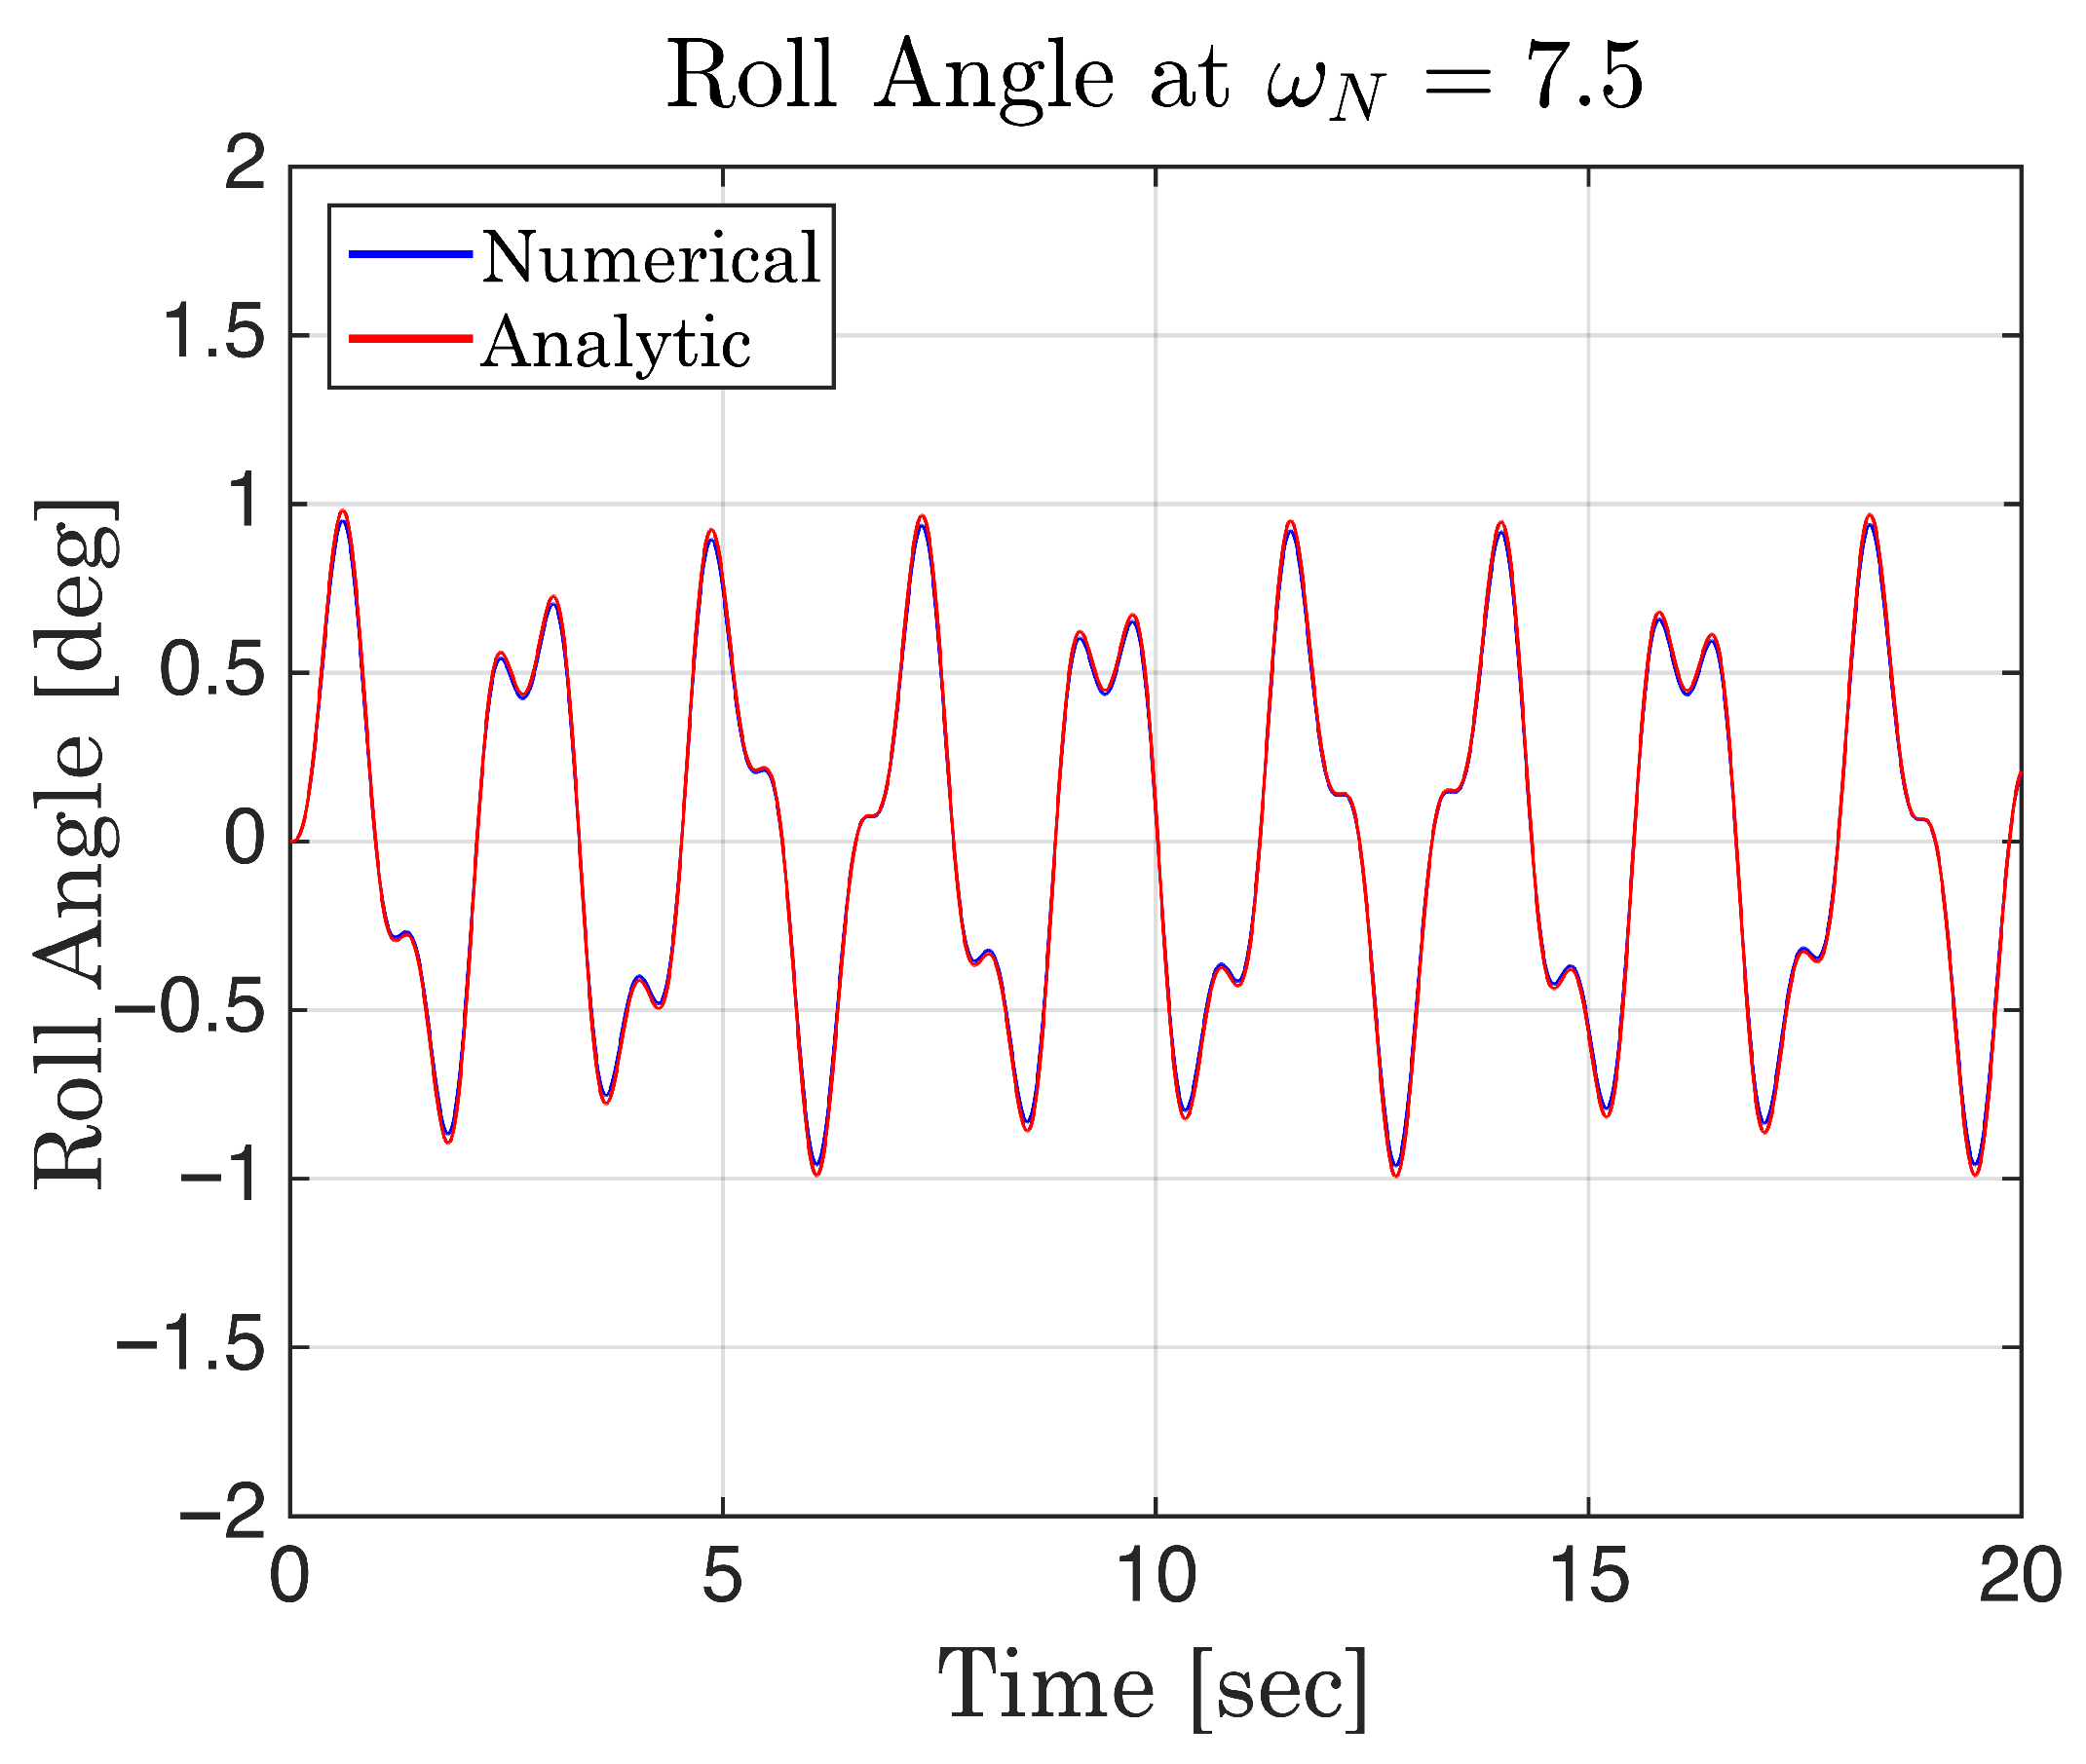
Figure 2 and Figure 3 shows the roll angle and the phase portrait of the model at , respectively. Figure 2 shows that roll angle is bounded within 1 deg due to . Furthermore, the profile of proposed analytic solution corresponds to that of numerical simulation. This result supports the verification of Theorem 1. Figure 3 shows that both roll angle and roll angular velocity keep small even if aerodynamic damping is ignored. Roll angles and phase portrait of the model at were shown in Figure 4 and Figure 5. When we compare Figure 2 and Figure 4, roll angles in Figure 4 keep increasing until 10 degs while roll angles in Figure 2 stay within 1 deg. Moreover, two phase portraits represented by Figure 3 and Figure 5 have significantly different qualitative behaviors.
Figure 2.
Roll angles: numerical simulation vs. analytic solution.
Figure 3.
Phase Portrait: numerical simulation vs. analytic solution.
Figure 4.
Roll angles: numerical simulation vs. analytic solution.
Figure 5.
Phase portrait: numerical simulation vs. analytic solution.
We simulate (4) to verify Theorem 2. From analytic solution, we know that roll angle can be diverged when equals ; that is, . However, actual system has aerodynamic damping that plays role in dissipating energy. Moreover, unknown bounded disturbances can increase roll angular velocity.
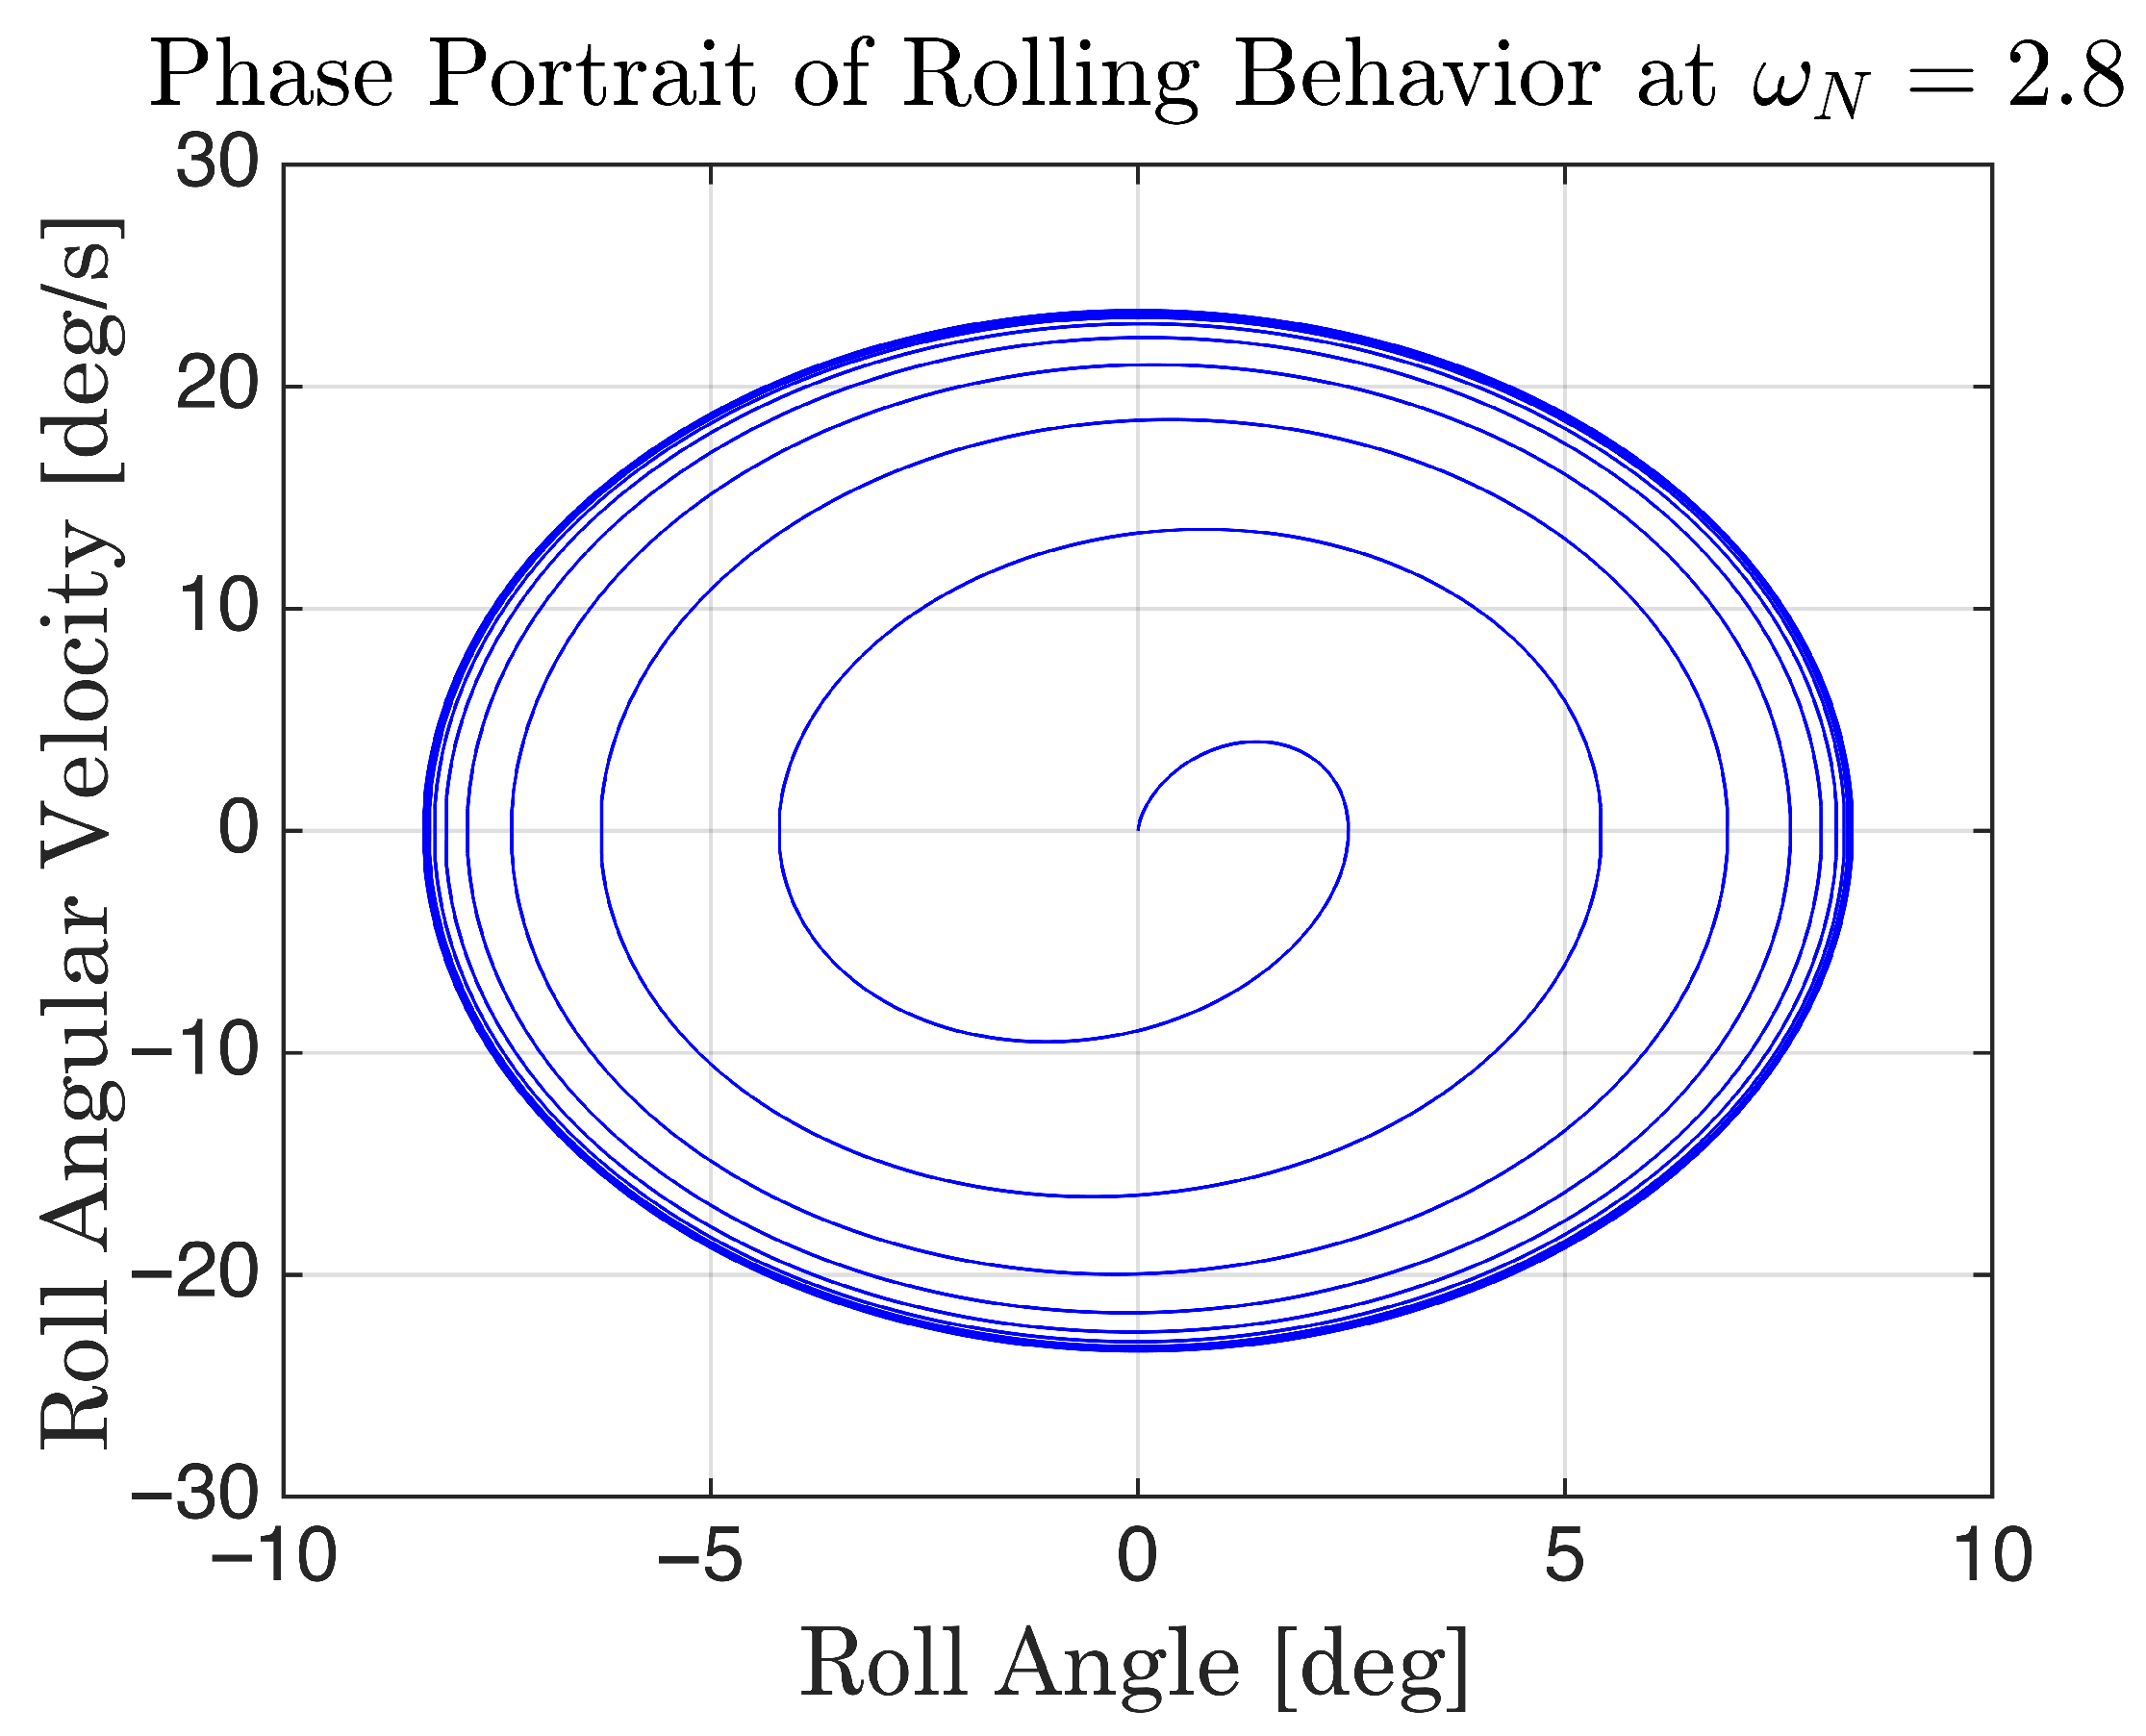
When , , and are selected, the absolute bound of roll angular velocity is 24 deg/s, which is computed by of Theorem 2. Figure 6 shows maximum bound of is 23.4 deg/s, which is almost equal to the theoretical bound.
Figure 6.
Phase portrait: Aerodynamic damping included.
6. Conclusions
This paper presents analytic solution of inducing rolling behaviors of robotic blimps. An uncontrollable model that represents rolling behaviors is developed as a class of nonlinear nonautonomous system without equilibrium points. The uncontrollable model is simplified by assuming small angles, no aerodynamic damping, and no unknown disturbances. We derive a general solution of the simplified model, analytically. From the analytic solution, we propose that a bandwidth of combined motions is far from the natural frequency caused by buoyancy moment for keeping roll angle small. In addition, we prove that the uncontrollable model including aerodynamic damping and unknown disturbances is ultimately bounded. For future study, we will design upward and sideway autopilots robust to inducing rolling behaviors.
Funding
This work was supported by the National Research Foundation of Korea(NRF) grant funded by the Korea government (MSIT) (RS2023-002792).
Data Availability Statement
The original contributions presented in this study are included in the article. Further inquiries can be directed to the corresponding author.
Conflicts of Interest
The author declares no conflict of interest.
References
- Cho, S.; Tao, Q.; Varnell, P.; Maxon, S.; Zhang, F. Autopilot design of a class of miniature autonomous blimps enabled by switched controllers. Int. J. Intell. Robot. Appl. 2022, 6, 385–396. [Google Scholar] [CrossRef] [Scilit]
- Müller, J.; Burgard, W. Efficient probabilistic localization for autonomous indoor airships using sonar, air flow, and IMU sensors. Adv. Robot. 2013, 27, 711–724. [Google Scholar] [CrossRef] [Scilit]
- Yamada, T.; Yairi, T.; Bener, S.H.; Machida, K. A Study on SLAM for Indoor Blimp with Visual Markers. In Proceedings of the ICROS-SICE International Joint Conference, Fukuoka, Japan, 18–21 August 2009; pp. 647–652. [Google Scholar]
- Burri, M.; Gasser, L.; Kach, M.; Laube, S.; Ledergerber, A. Design and Control of a Spherical Omnidirectional Blimp. In Proceedings of the IEEE/RSJ International Conference on Intelligent Robots and Systems, Tokyo, Japan, 3–7 November 2013; pp. 1873–1879. [Google Scholar]
- Zwann, S.; Bernardino, A.; Santos-Victor, J. Vision based Station Keeping and Docking for an Aerial Blimp. In Proceedings of the 2000 IEEE/RSJ International Conference on Intelligent Robots and Systems, Takamatsu, Japan, 31 October–5 November 2000; pp. 614–619. [Google Scholar]
- Kantor, G.; Wettergreen, D.; Ostrowski, J.P.; Singh, S. Collection of environmental data from an airship platform. In Proceedings of the SPIE Conference on Sensor Fusion and Decentralized Control IV, Newton, MA, USA, 28–29 October 2001; Volume 4571, pp. 76–83. [Google Scholar]
- Yamagata, Y.; Kawamura, H.; Ohuchi, A.; Takaya, T.; Iizuka, H. Simulation and implement of Memory-based PID control for indoor blimp robot. In Proceedings of the The Thirteenth International Symposium on Artificial Life and Robotics 2008, Oita, Japan, 31 January–2 February 2008; pp. 151–154. [Google Scholar]
- Cho, S.; Mishra, V.; Tao, Q.; Varnell, P.; King-Smith, M.; Muni, A.; Smallwood, W.; Zhang, F. Autopilot Design for A Class of Miniature Autonomous Blimps. In Proceedings of the 2017 IEEE International Conference on Control Technology and Applications, Maui, HI, USA, 27–30 August 2017; pp. 841–846. [Google Scholar]
- Pheh, Y.H.; Win, S.K.H.; Foong, S. SpICED: Design and Control of a Safe Spherical Blimp using Coandă Effect. In Proceedings of the 2021 IEEE/ASME International Conference on Advanced Intelligent Mechatronics, Delft, The Netherlands, 12–16 July 2021; pp. 270–277. [Google Scholar]
- Tao, Q.; Wang, J.; Xu, Z.; Lin, T.X.; Yuan, Y.; Zhang, F. Swing-Reducing Flight Control System for an Underactuated Indoor Miniature Autonomous Blimp. IEEE/ASME Trans. Mechatron. 2021, 26, 1895–1904. [Google Scholar] [CrossRef] [Scilit]
- Qu, Y.; Cai, L. Nonlinear Positioning Control for Underactuated Unmanned Surface Vehicles in the Presence of Environmental Disturbances. IEEE/ASME Trans. Mechatron. 2022, 27, 5381–5391. [Google Scholar] [CrossRef] [Scilit]
- Fantoni, I.; Lozano, R.; Spong, M.W. Energy Based Control of the Pendubot. IEEE Trans. Autom. Control 2000, 45, 725–729. [Google Scholar] [CrossRef] [Scilit]
- Cao, Q.; Guo, X. Anti-periodic dynamics on high-order inertial Hopfield neural networks involving time-varying delays. AIMS Math. 2020, 5, 5402–5421. [Google Scholar] [CrossRef] [Scilit]
- Hatchondo, L.; Guillevin, C.; Naudin, M.; Cherfils, L.; Miranville, A.; Guillevin, R. Mathematical modeling of brain metabolites variations in the circadian rhythm. AIMS Math. 2020, 5, 216–225. [Google Scholar] [CrossRef] [Scilit]
- Zhou, M.; Liang, Y.; Zhou, Y. Existence of Global Mild Solutions for Nonautonomous Abstract Evolution Equations. Mathematics 2025, 13, 1722. [Google Scholar] [CrossRef] [Scilit]
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2025 by the author. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).