Article

Kuramoto Object-Centric Reinforcement Learning for Robotic Manipulation Tasks

by
Leonid Ugadiarov
1,2 and
Aleksandr Panov
1,2,*
1
Moscow Independent Research Institute of Artificial Intelligence, 117218 Moscow, Russia
2
Cognitive AI Systems Lab, 123317 Moscow, Russia
*
Author to whom correspondence should be addressed.
Technologies 2026, 14(5), 266; https://doi.org/10.3390/technologies14050266

Submission received: 18 March 2026 / Revised: 23 April 2026 / Accepted: 24 April 2026 / Published: 28 April 2026

Abstract

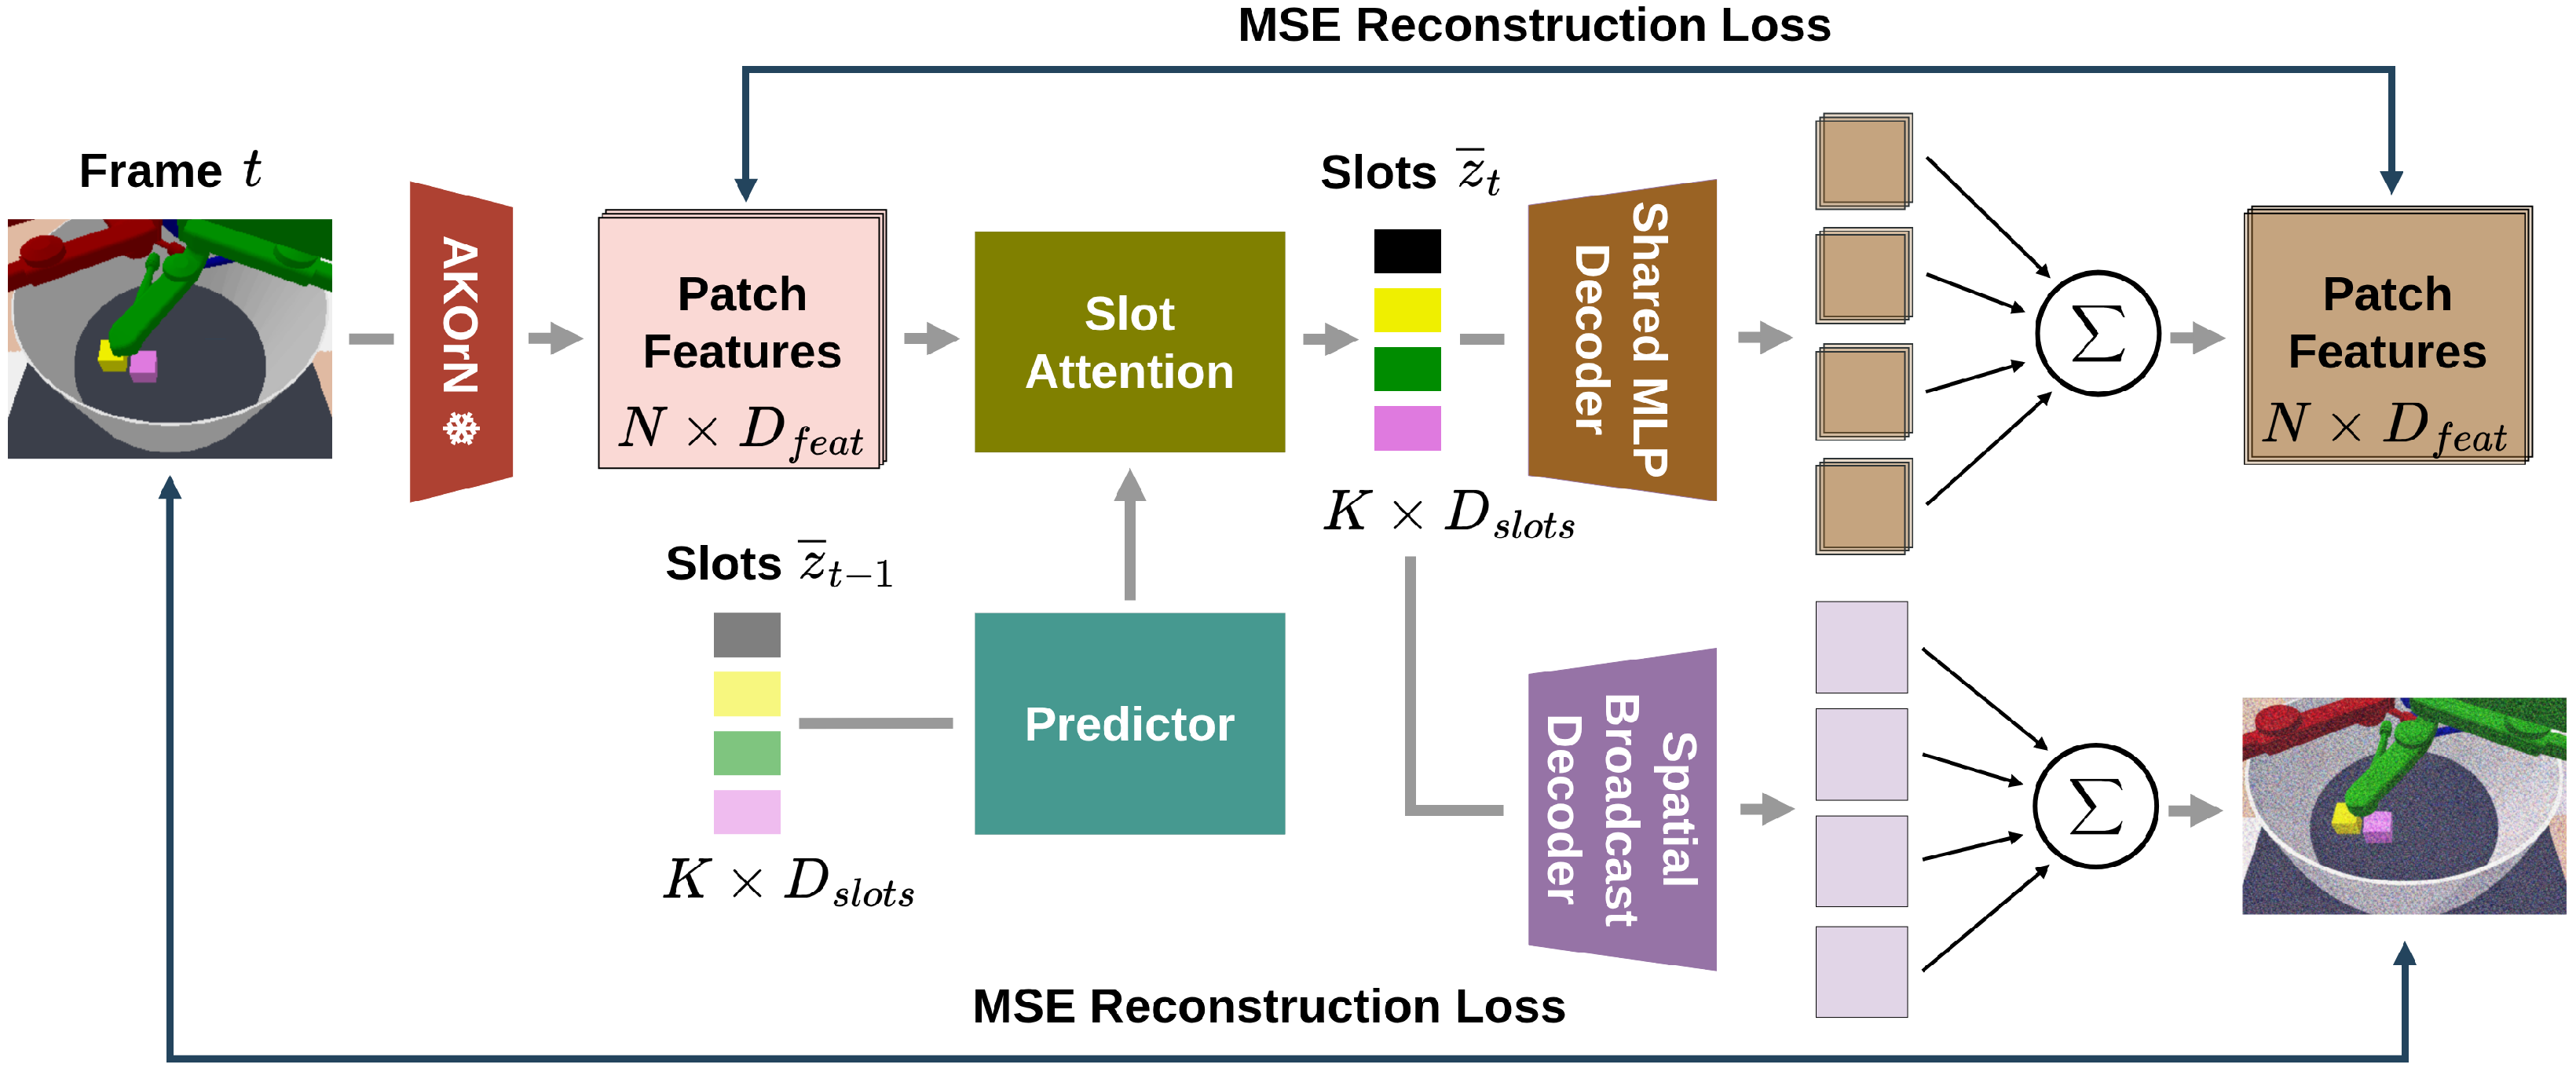
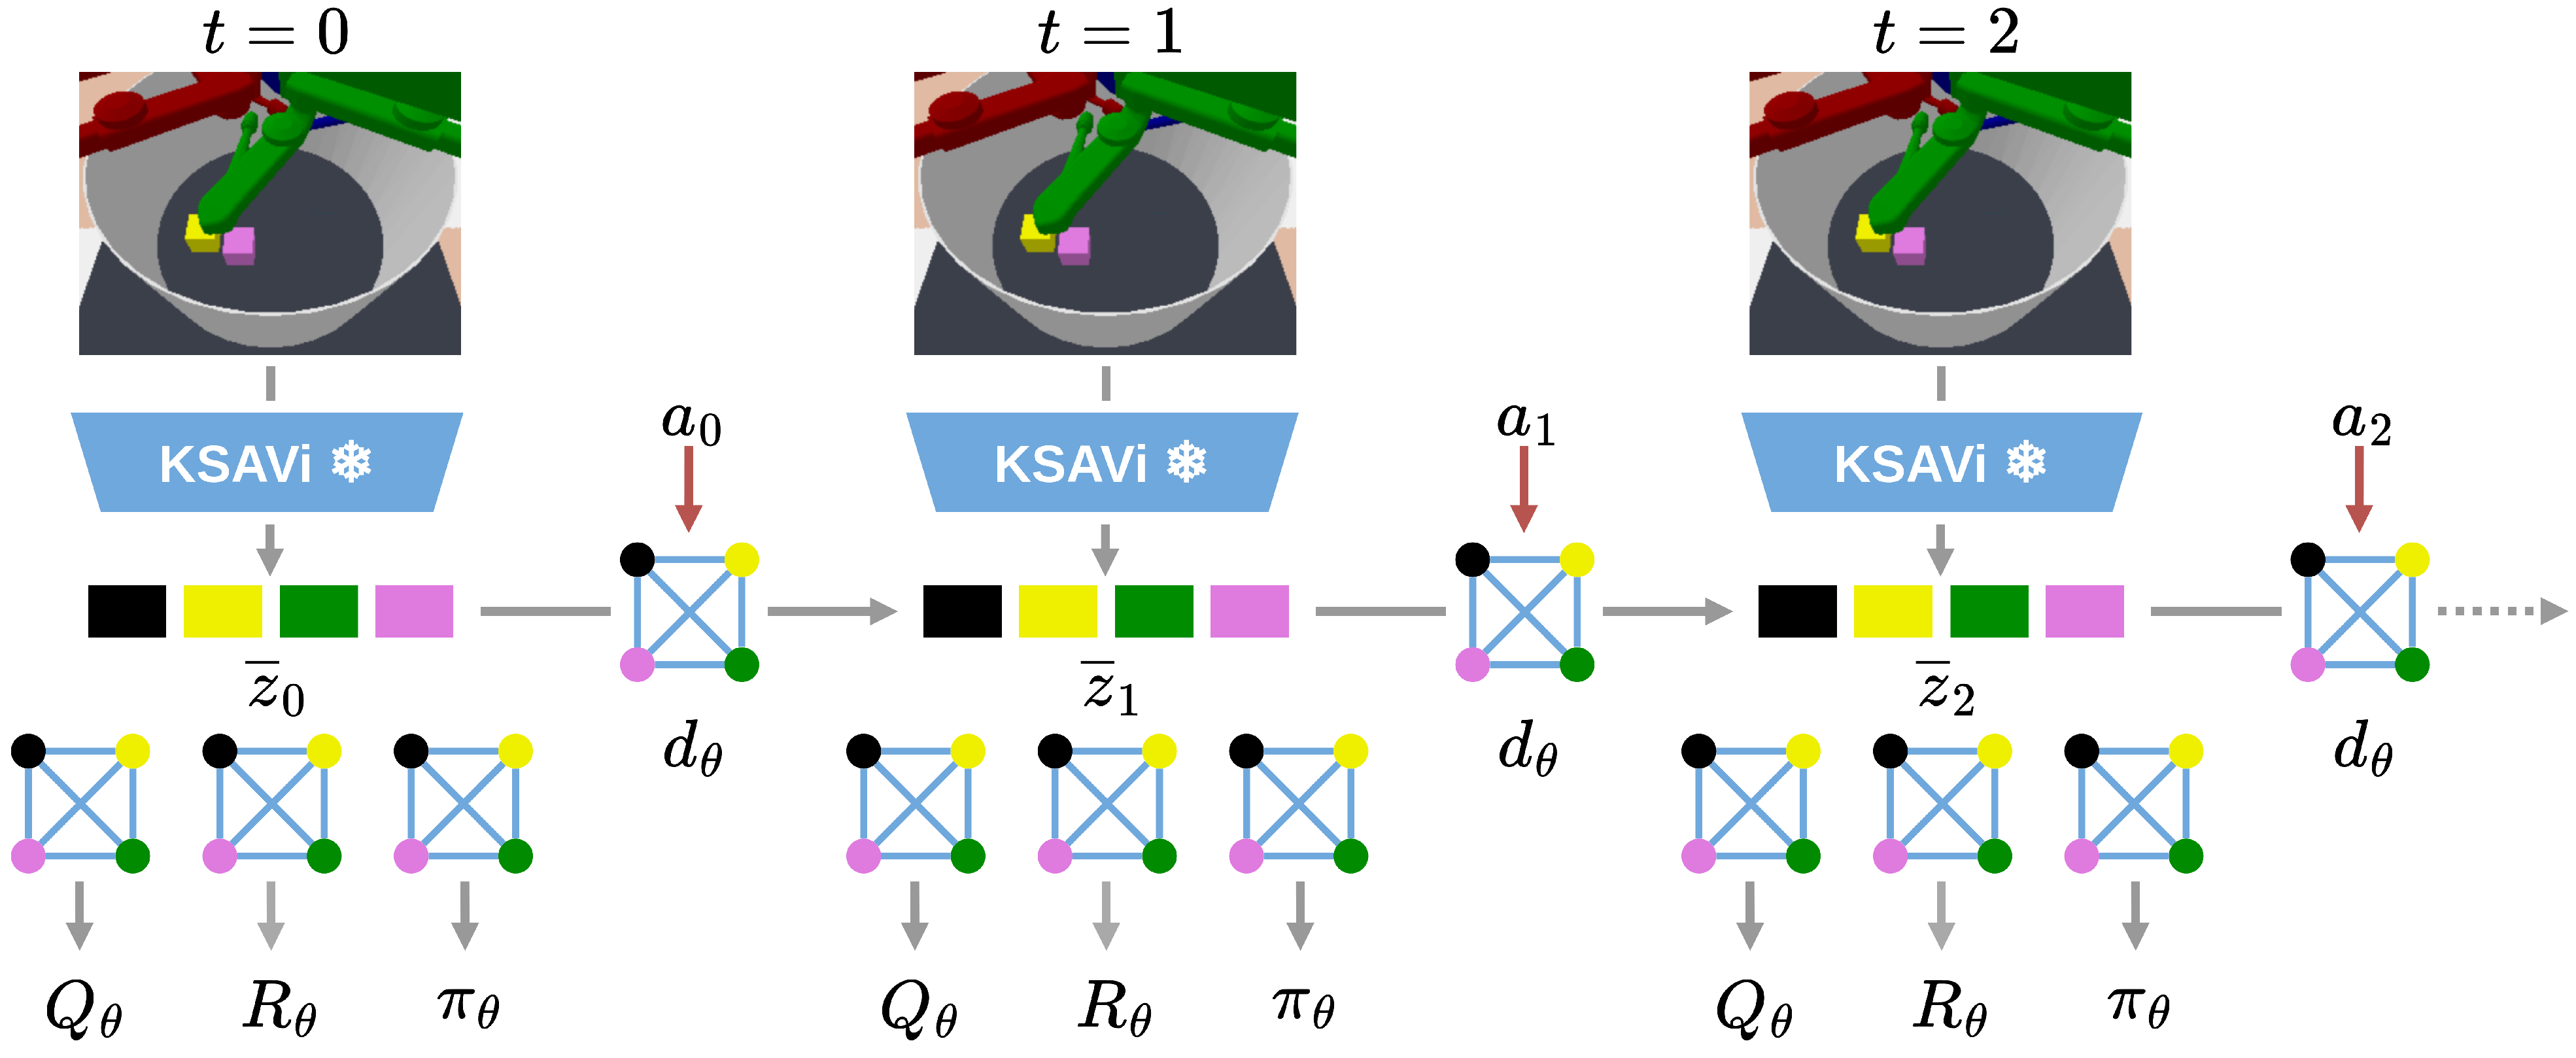
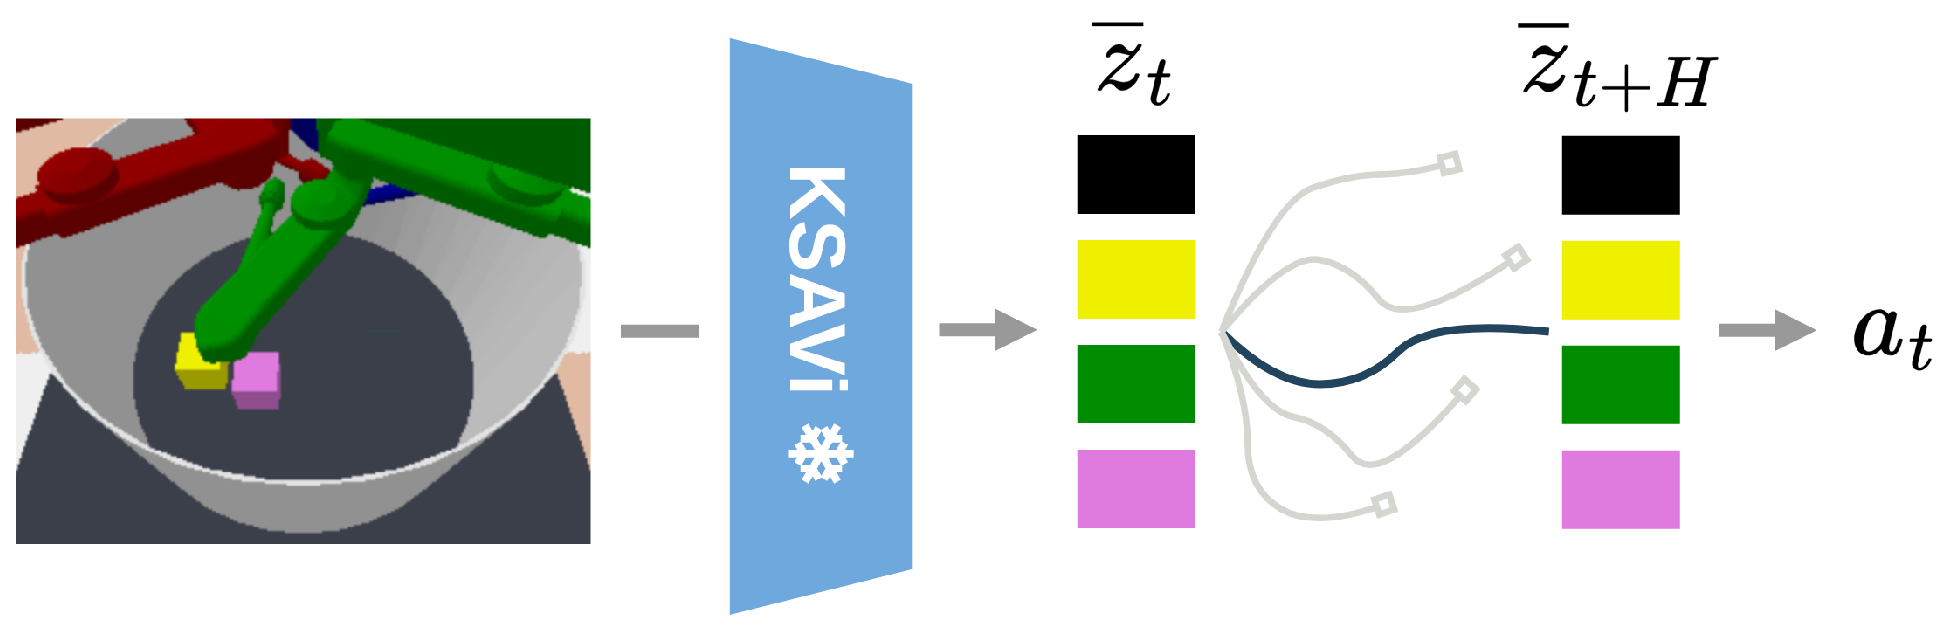
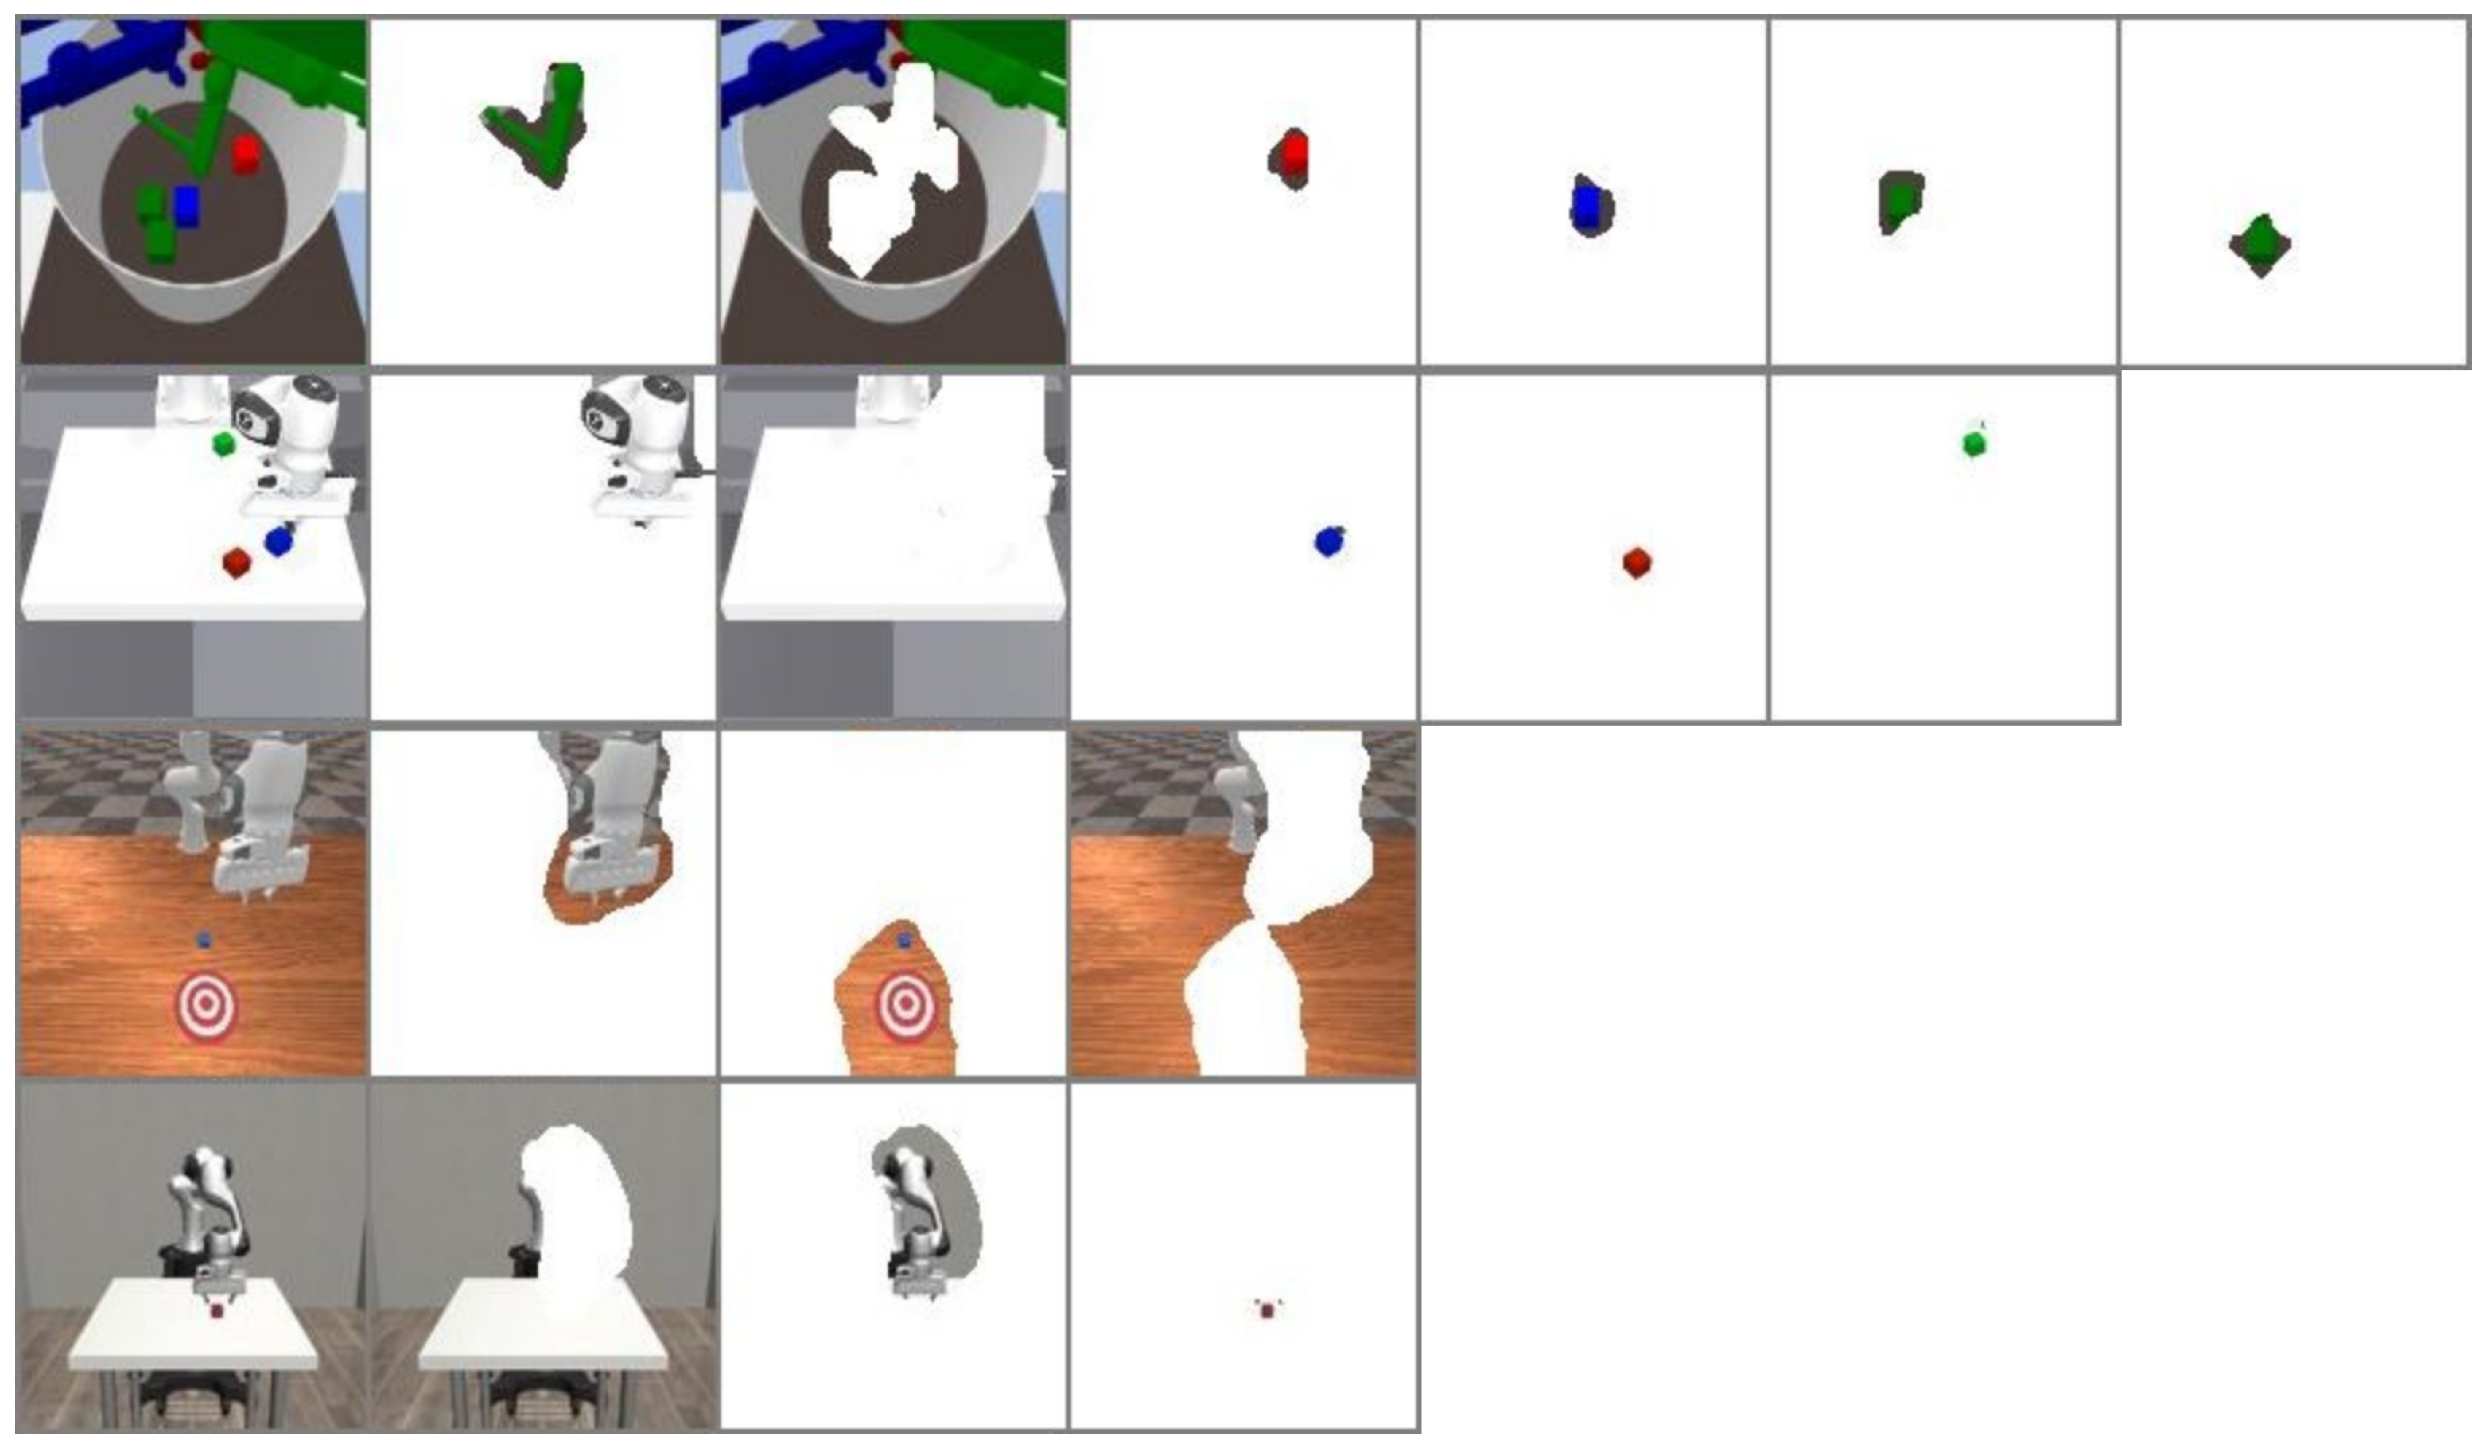
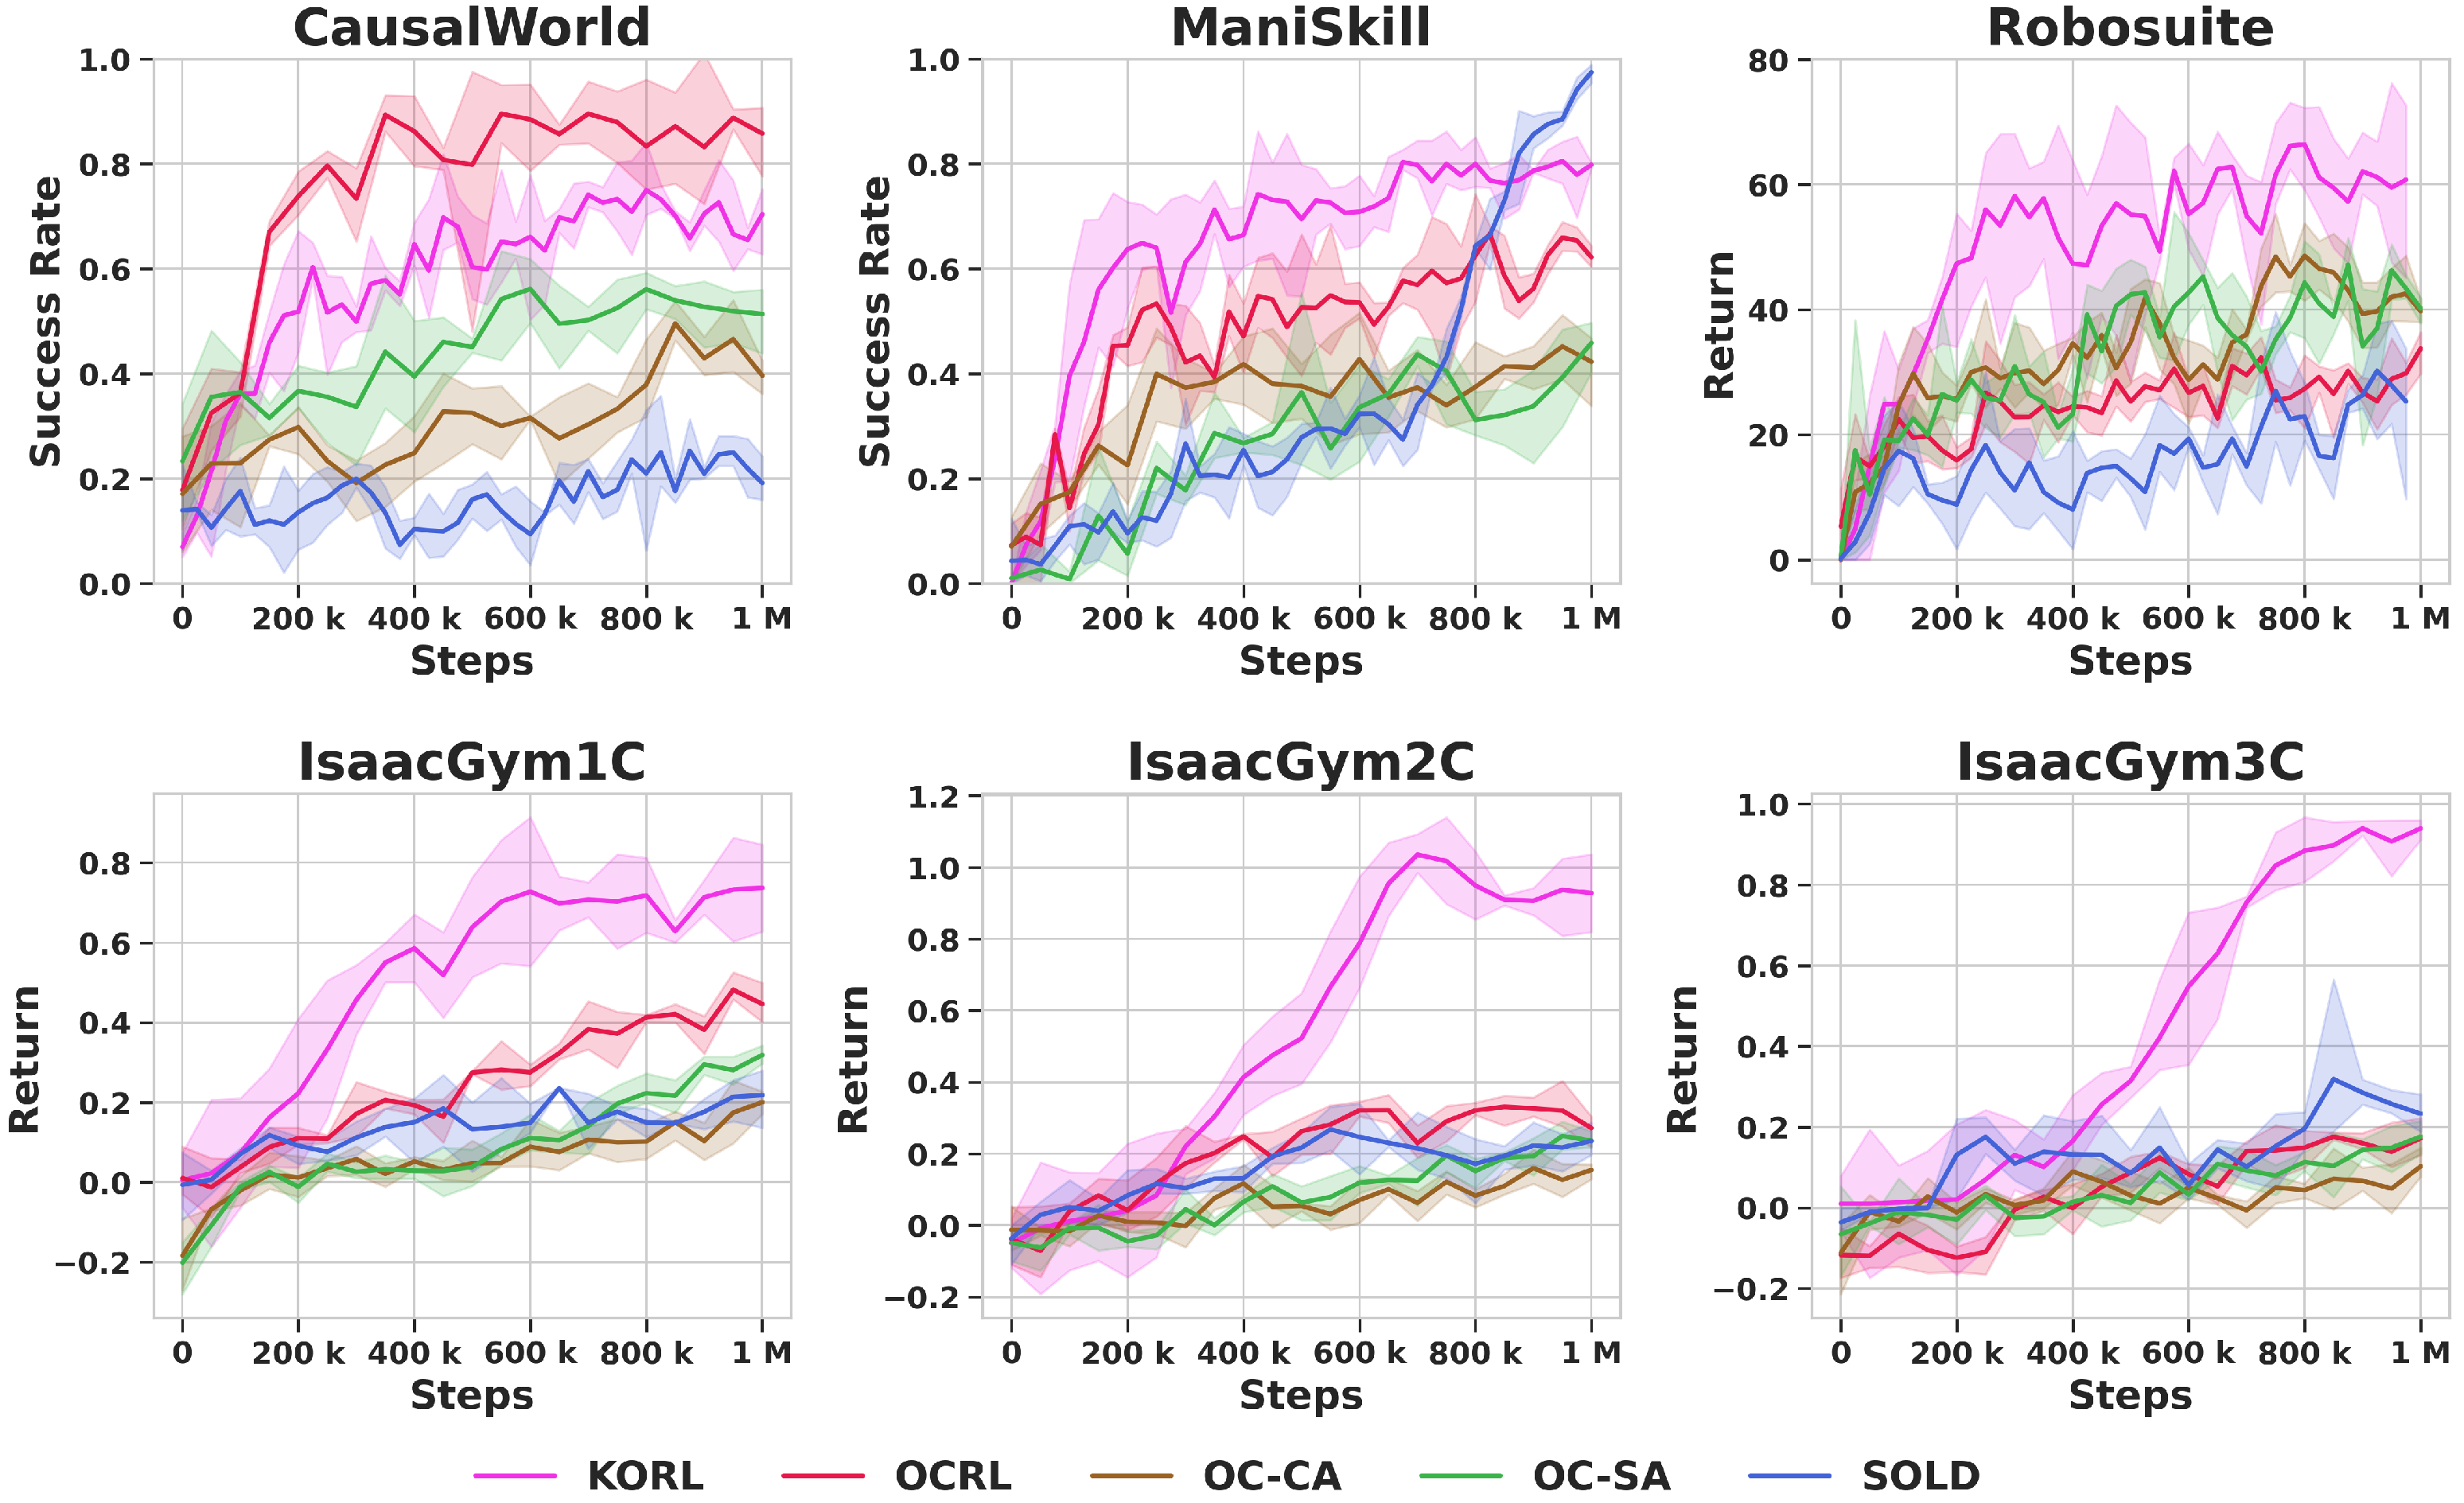
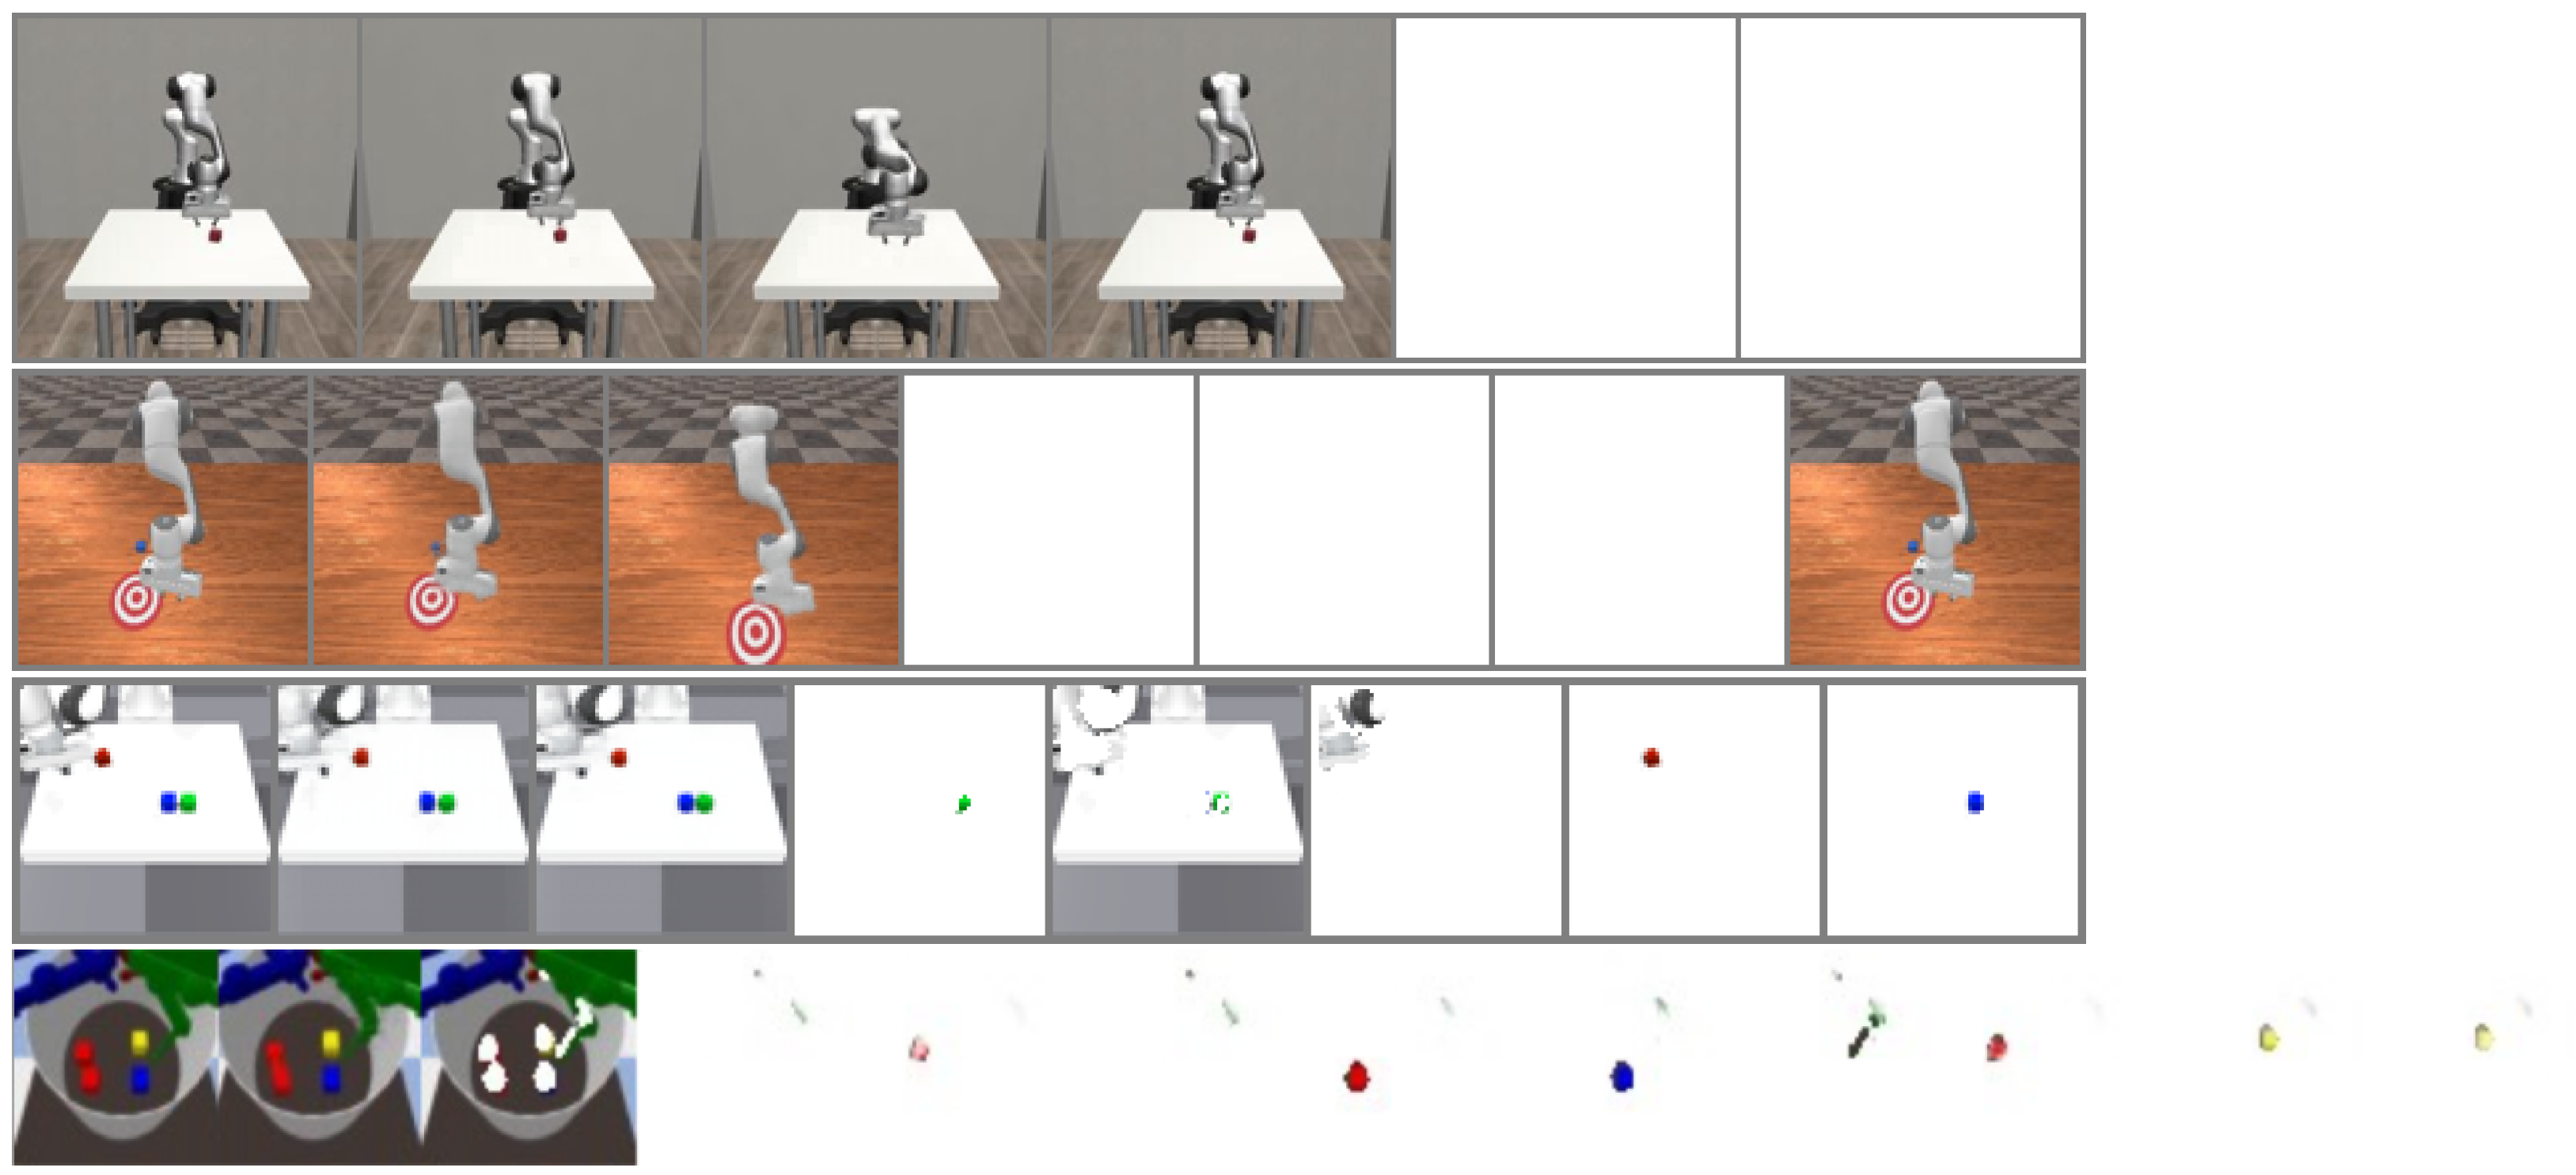
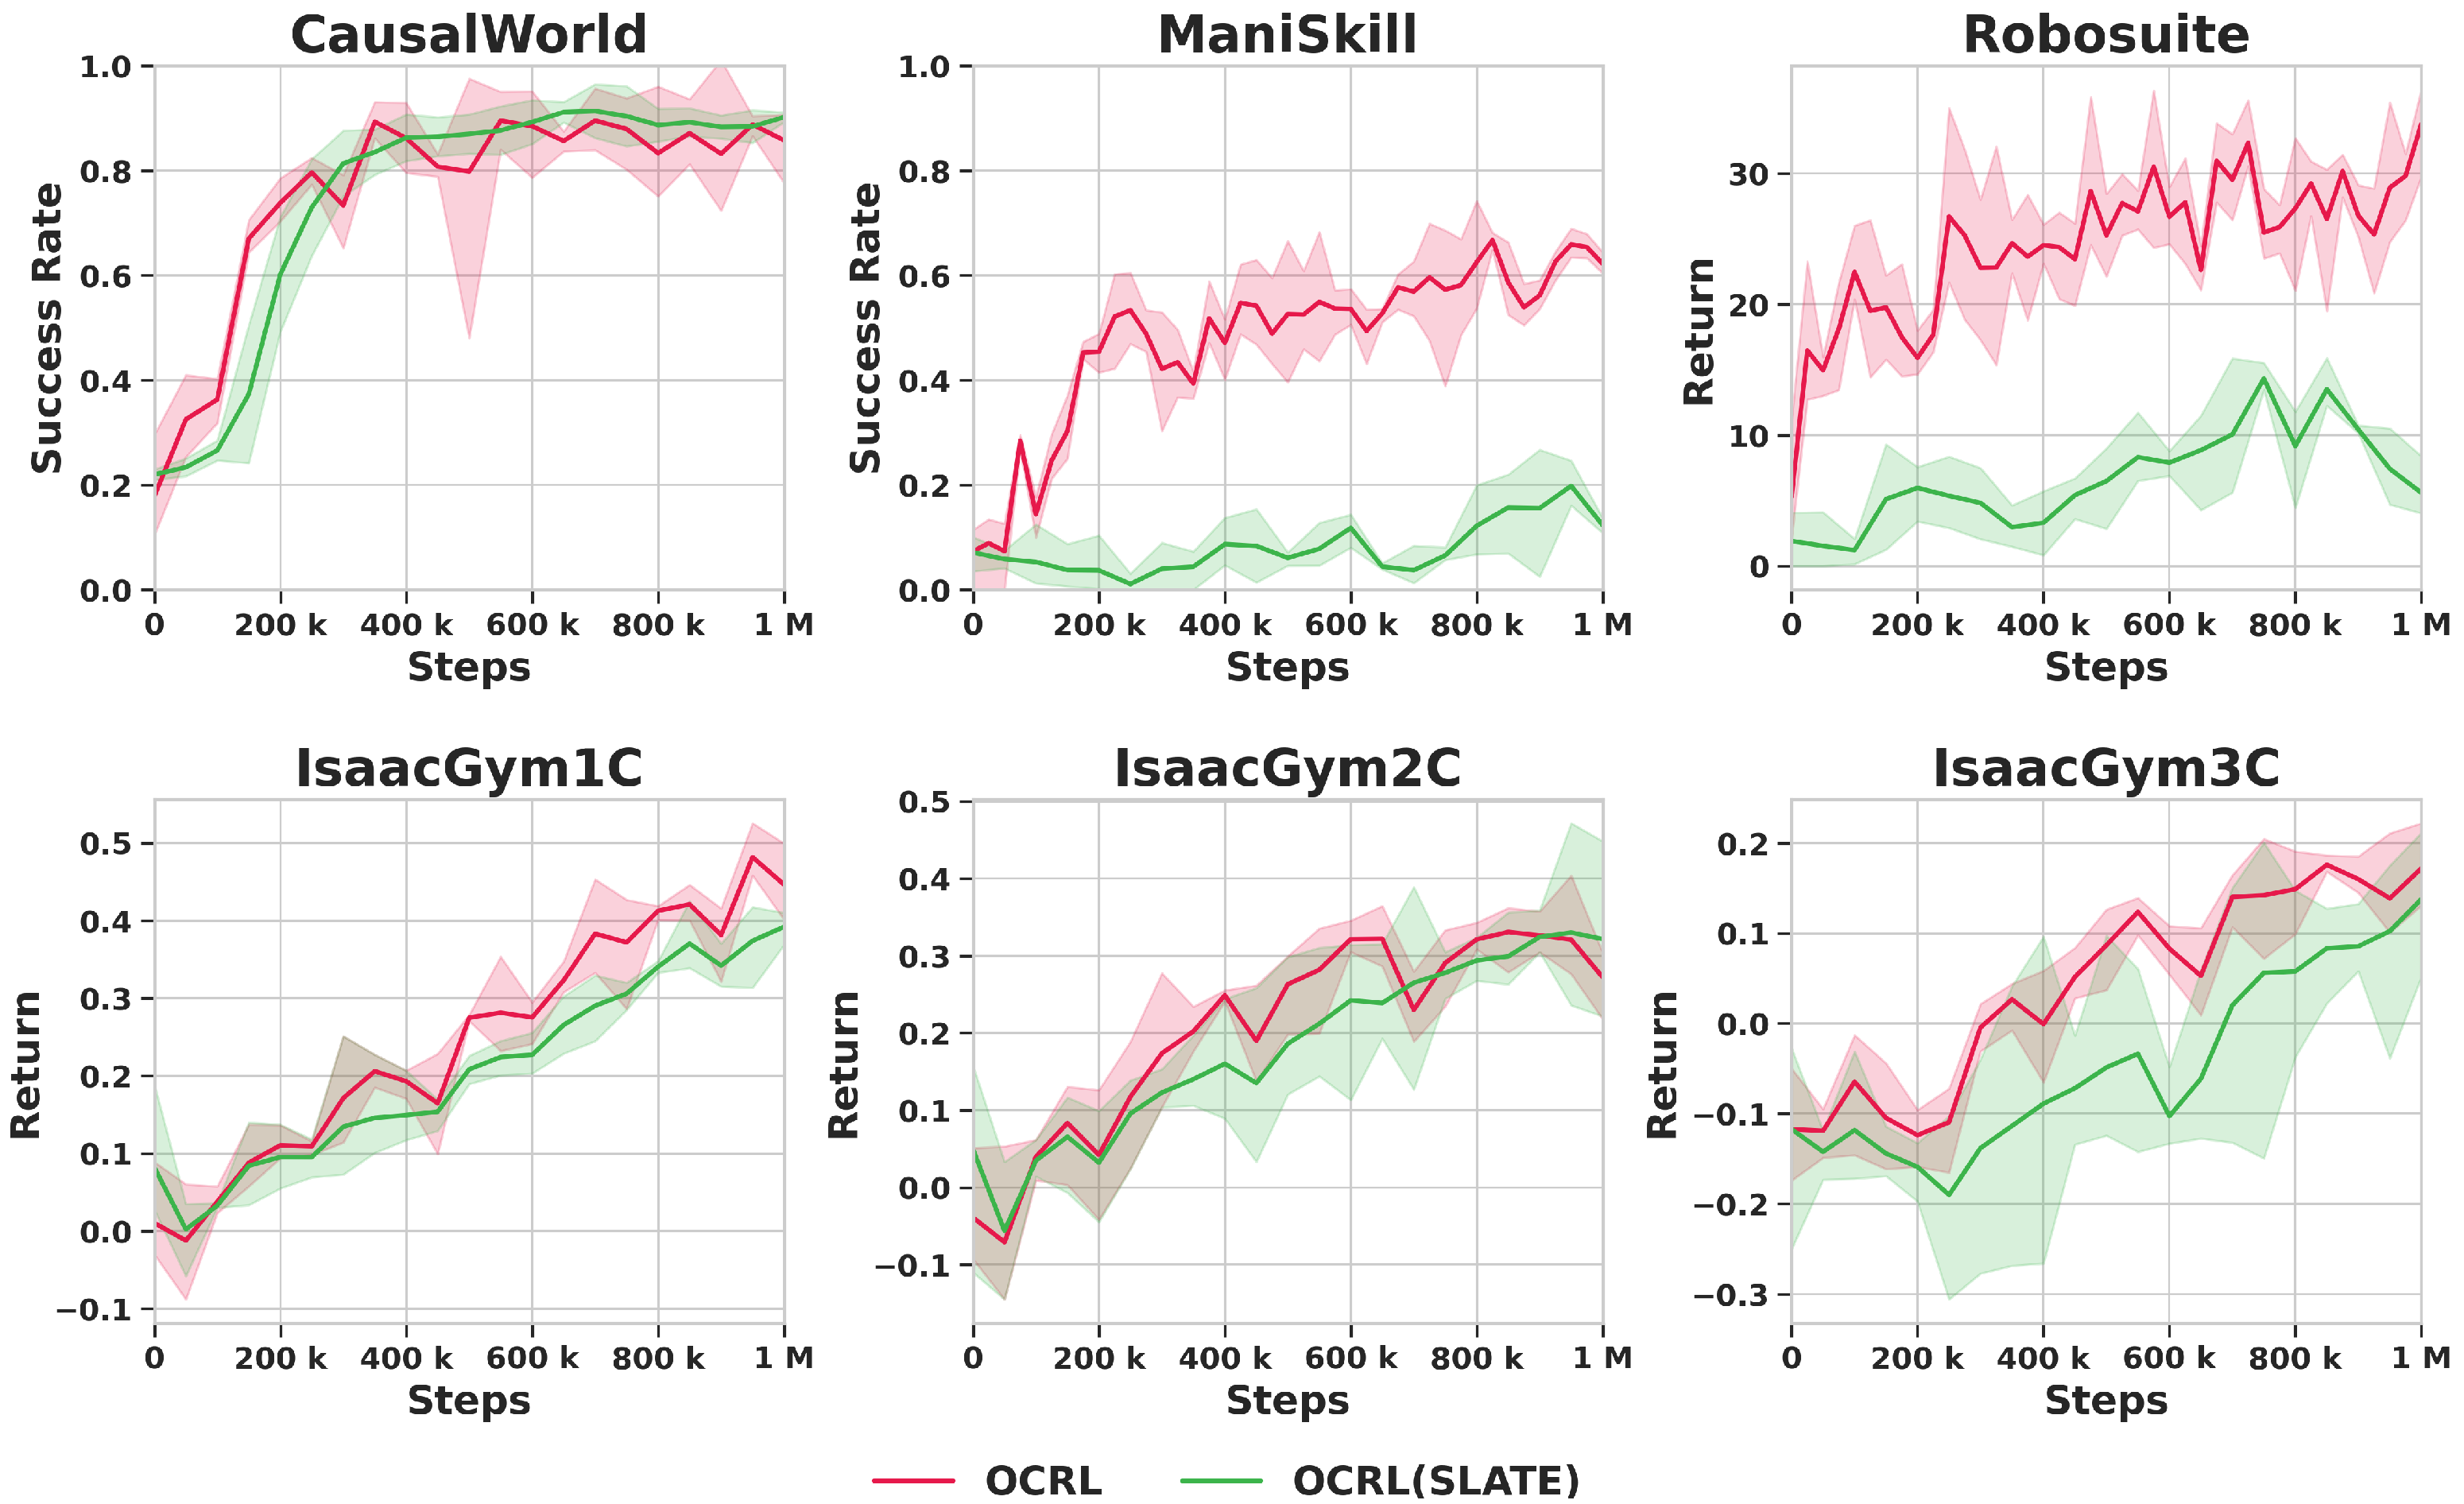
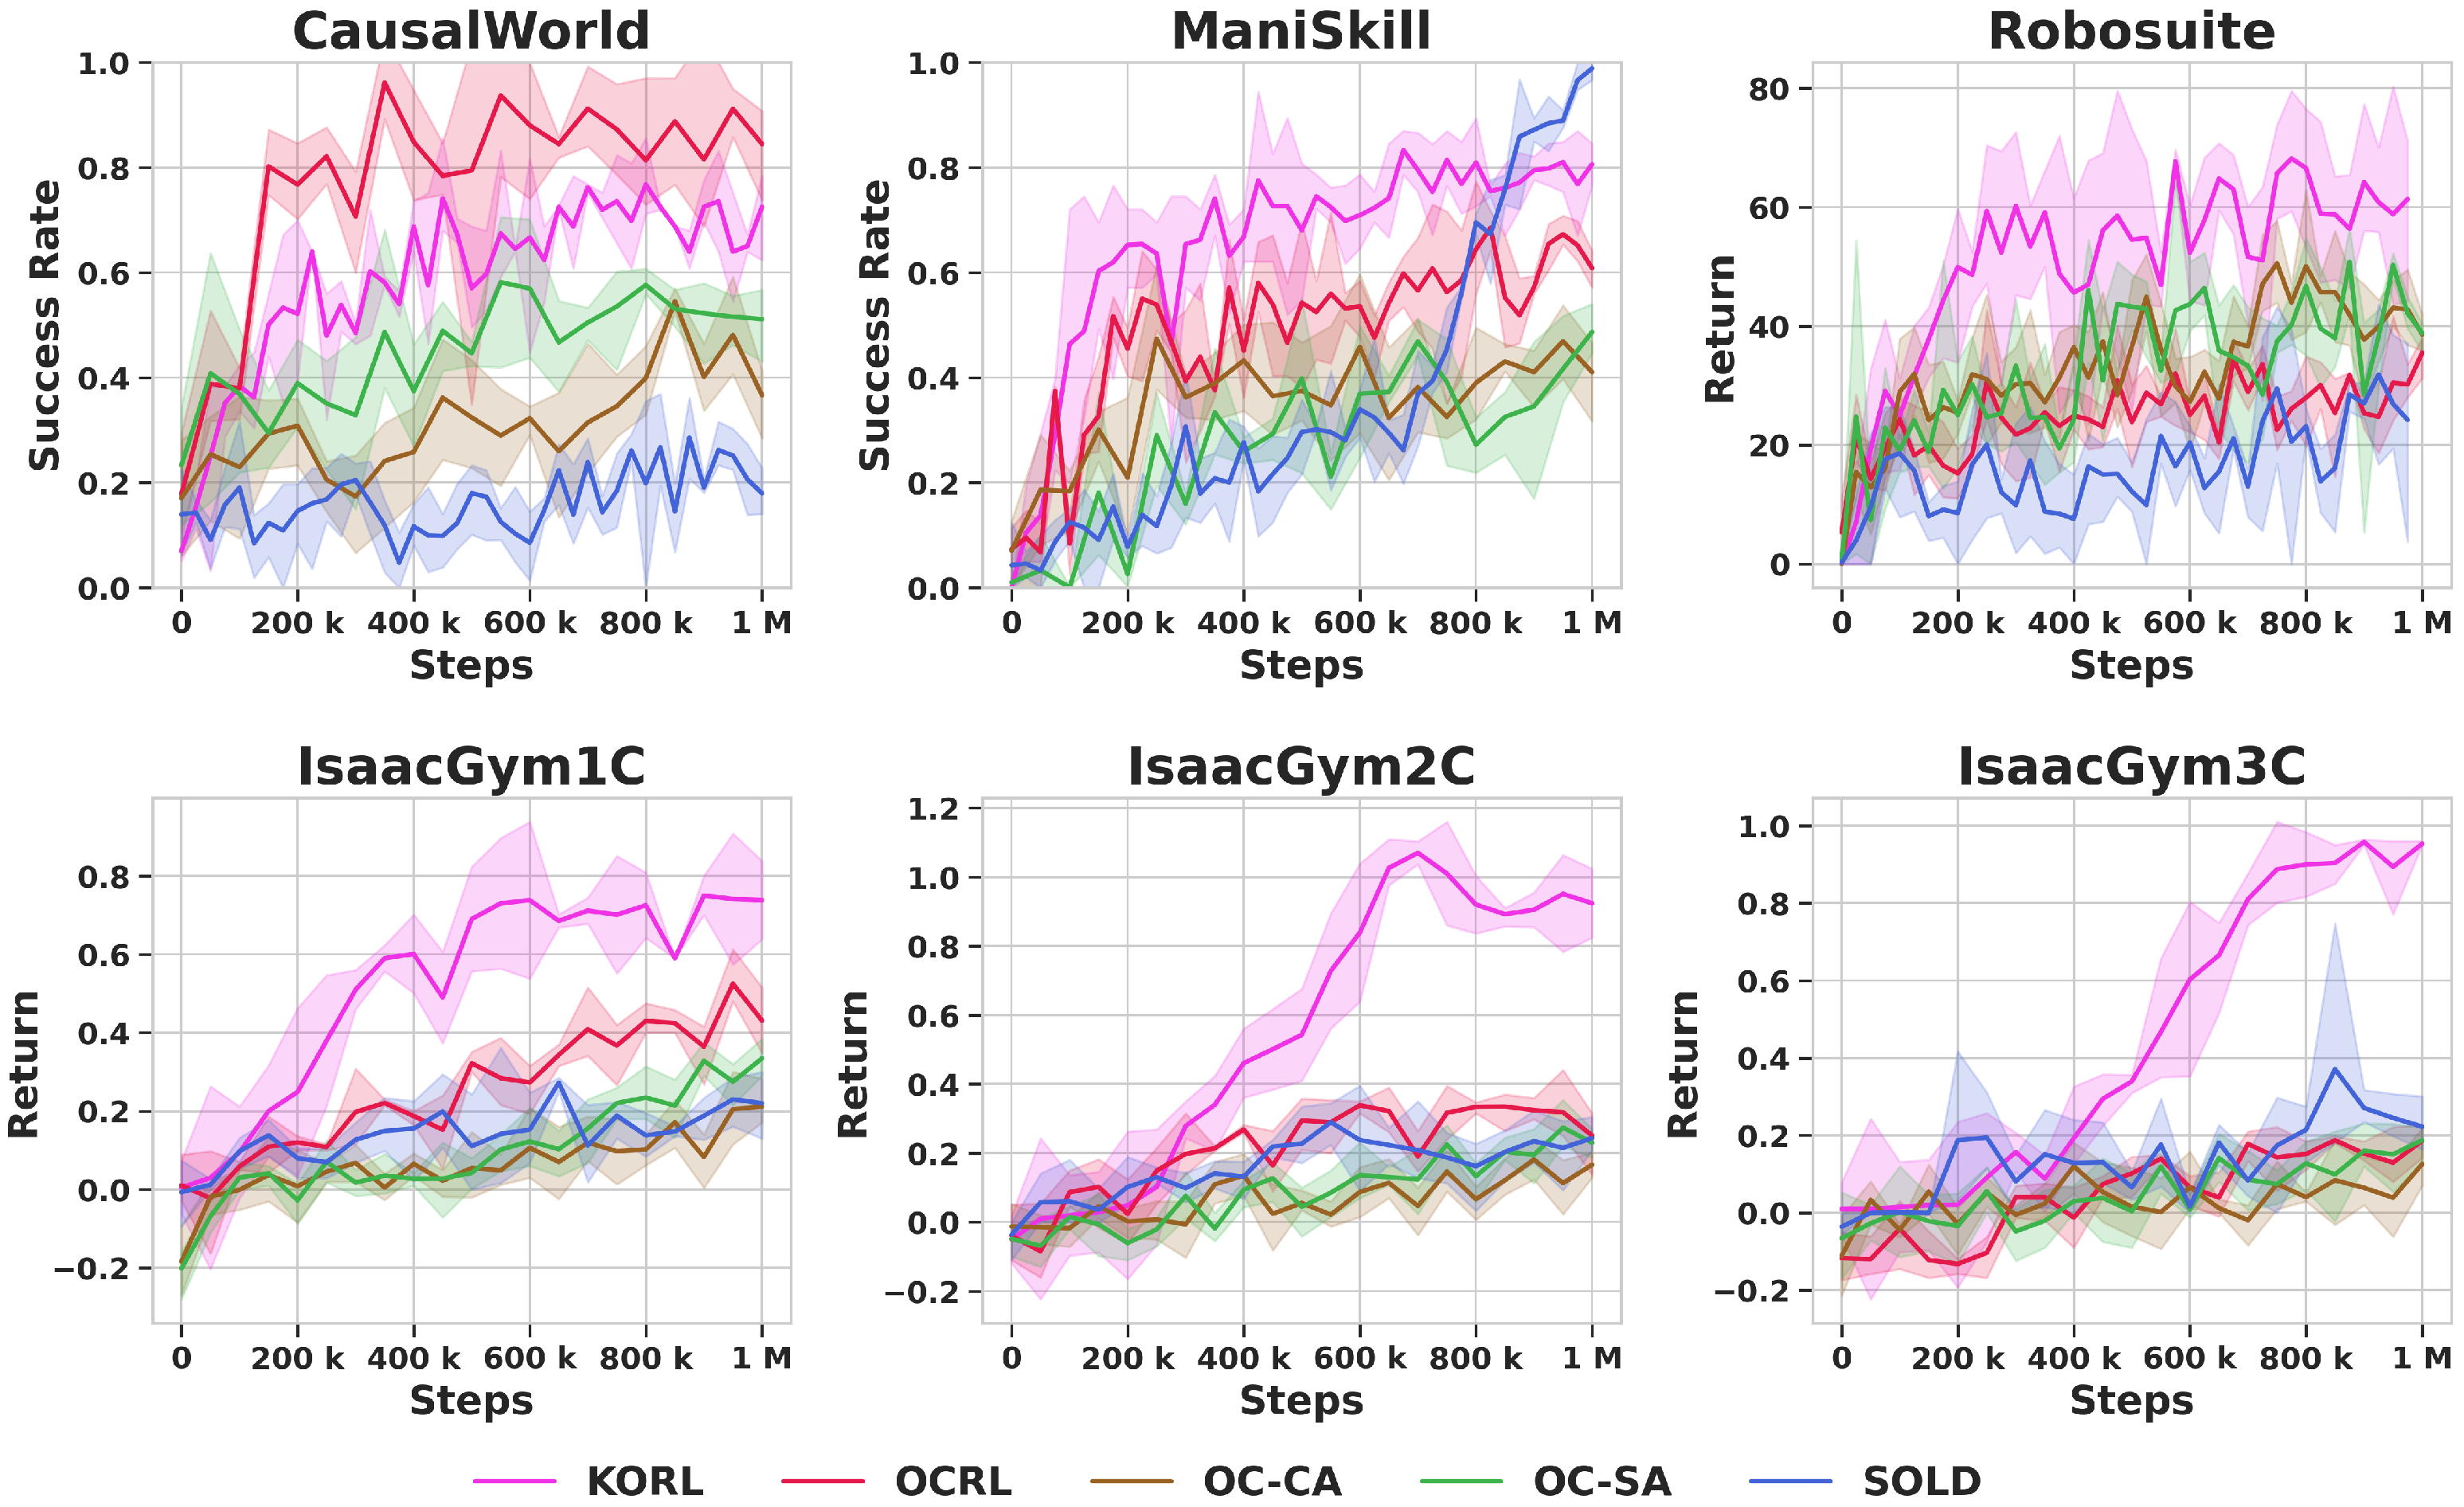
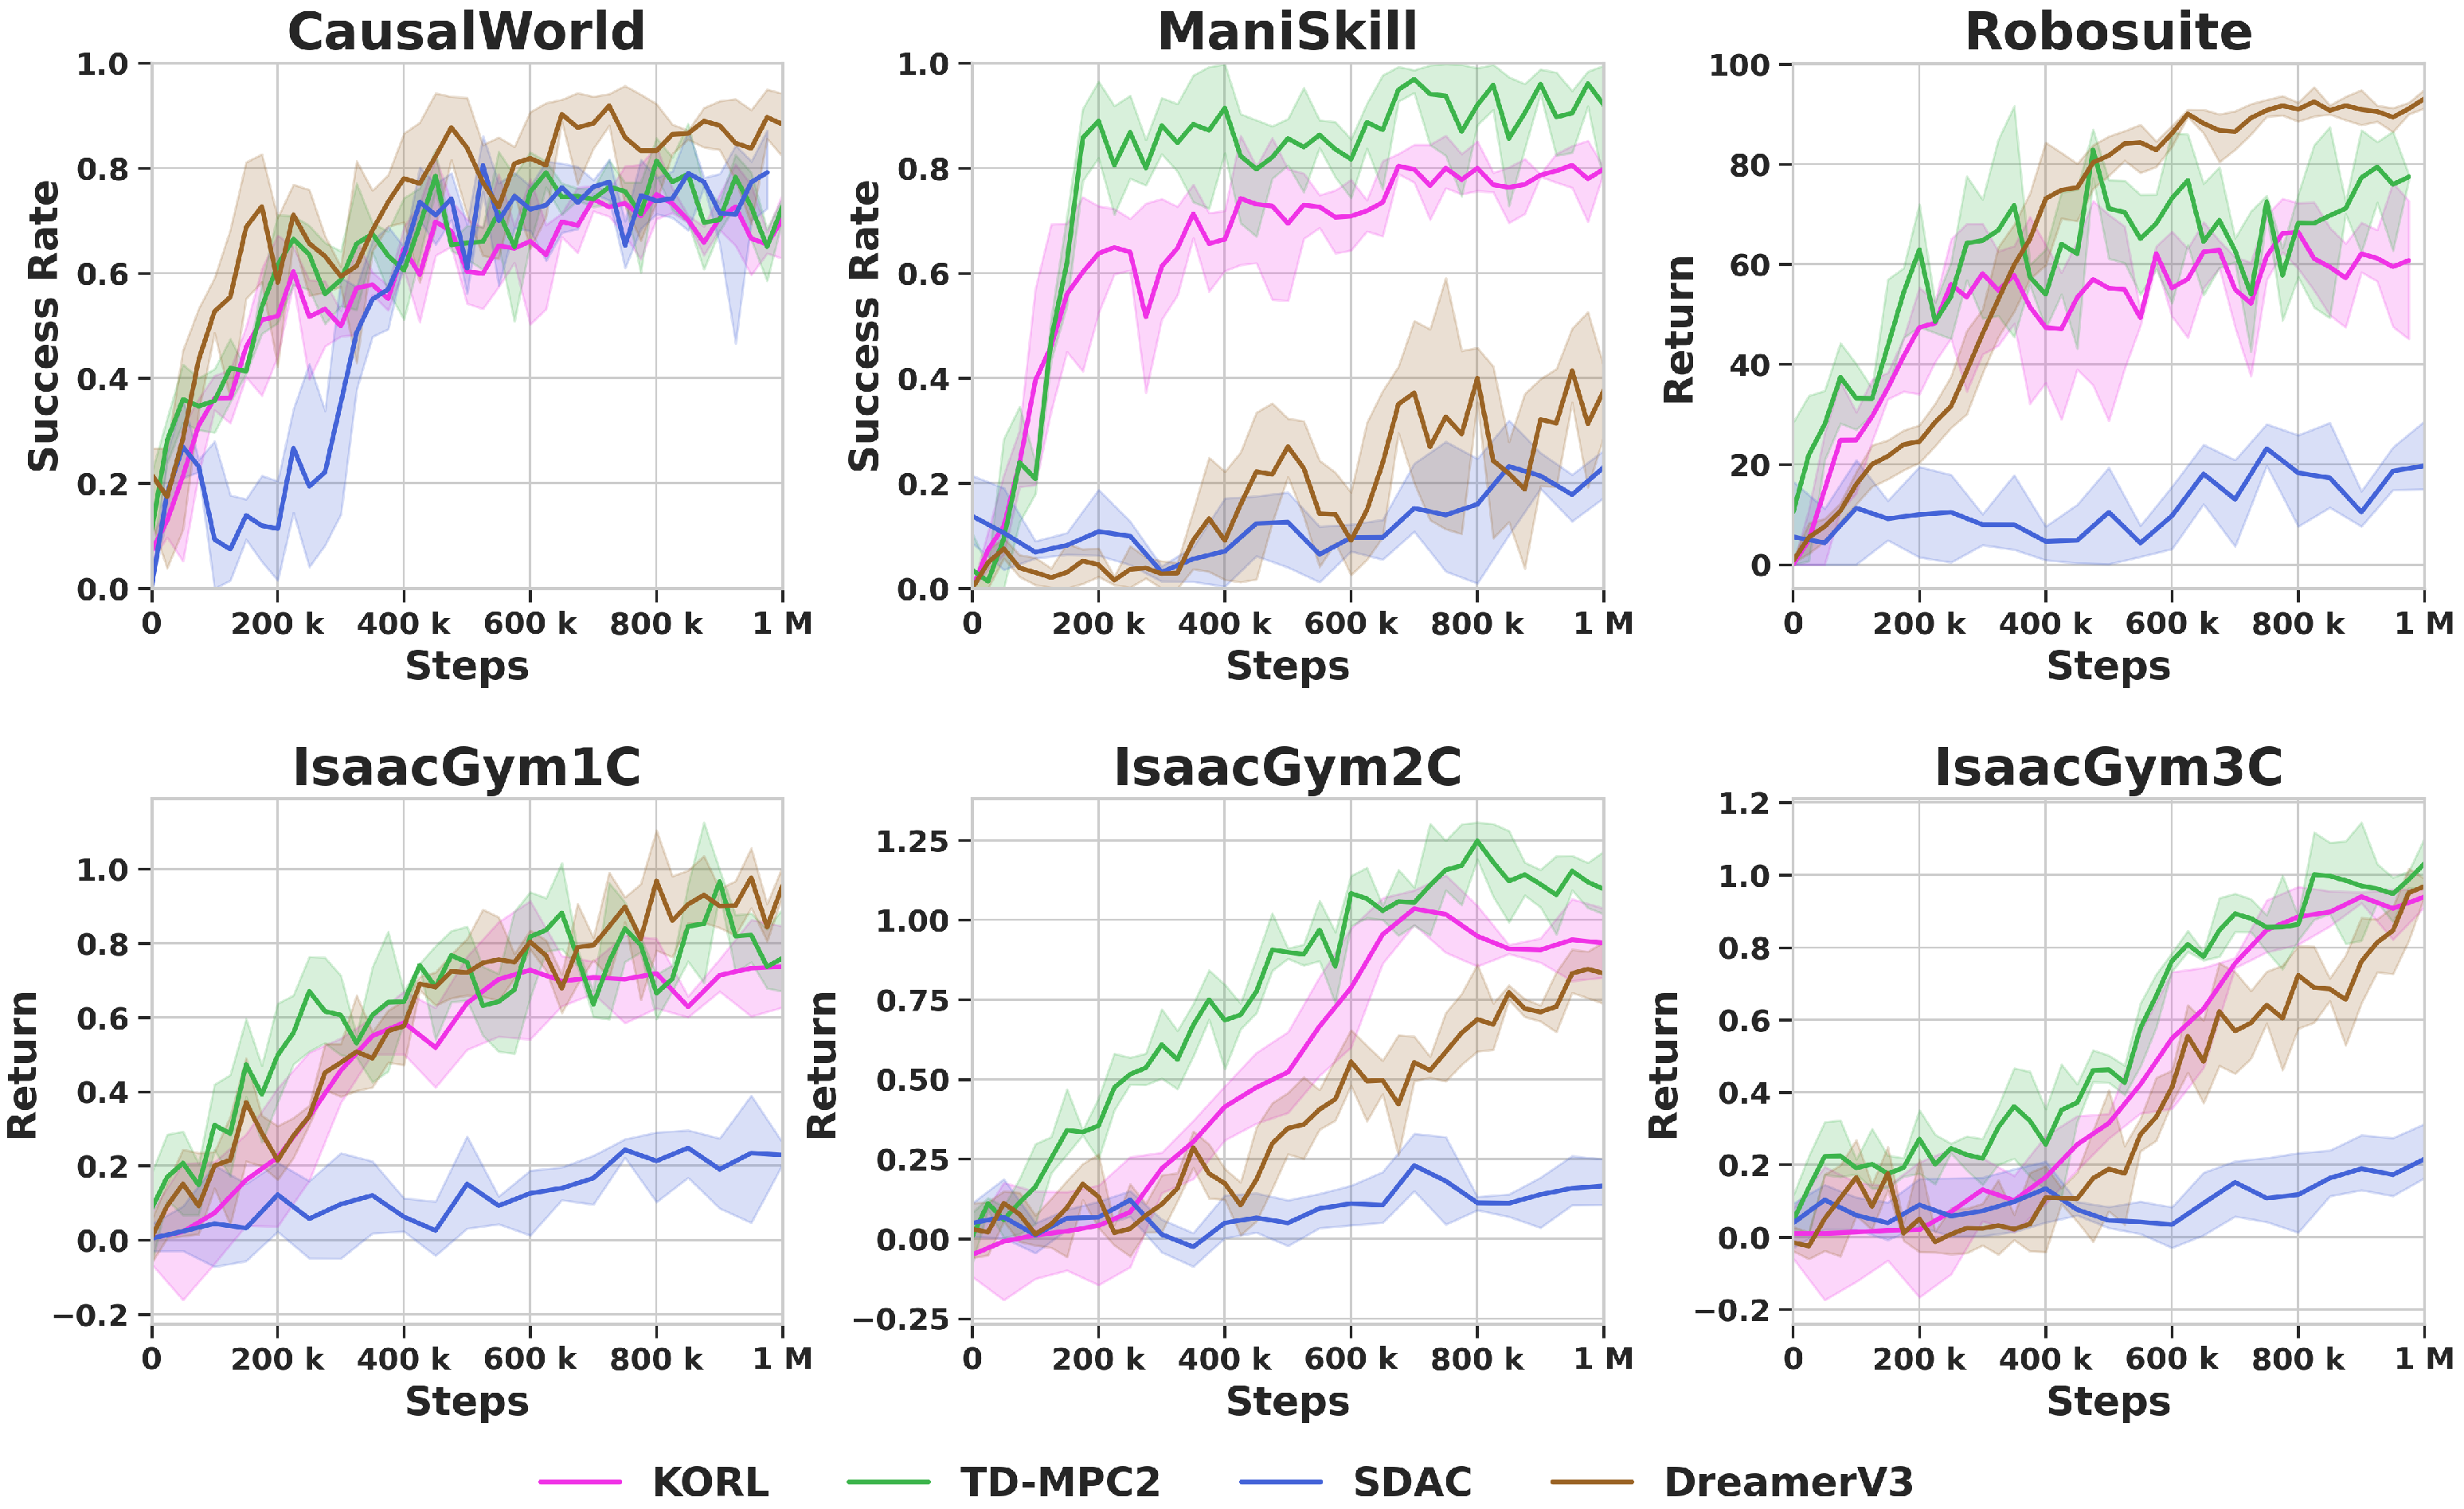
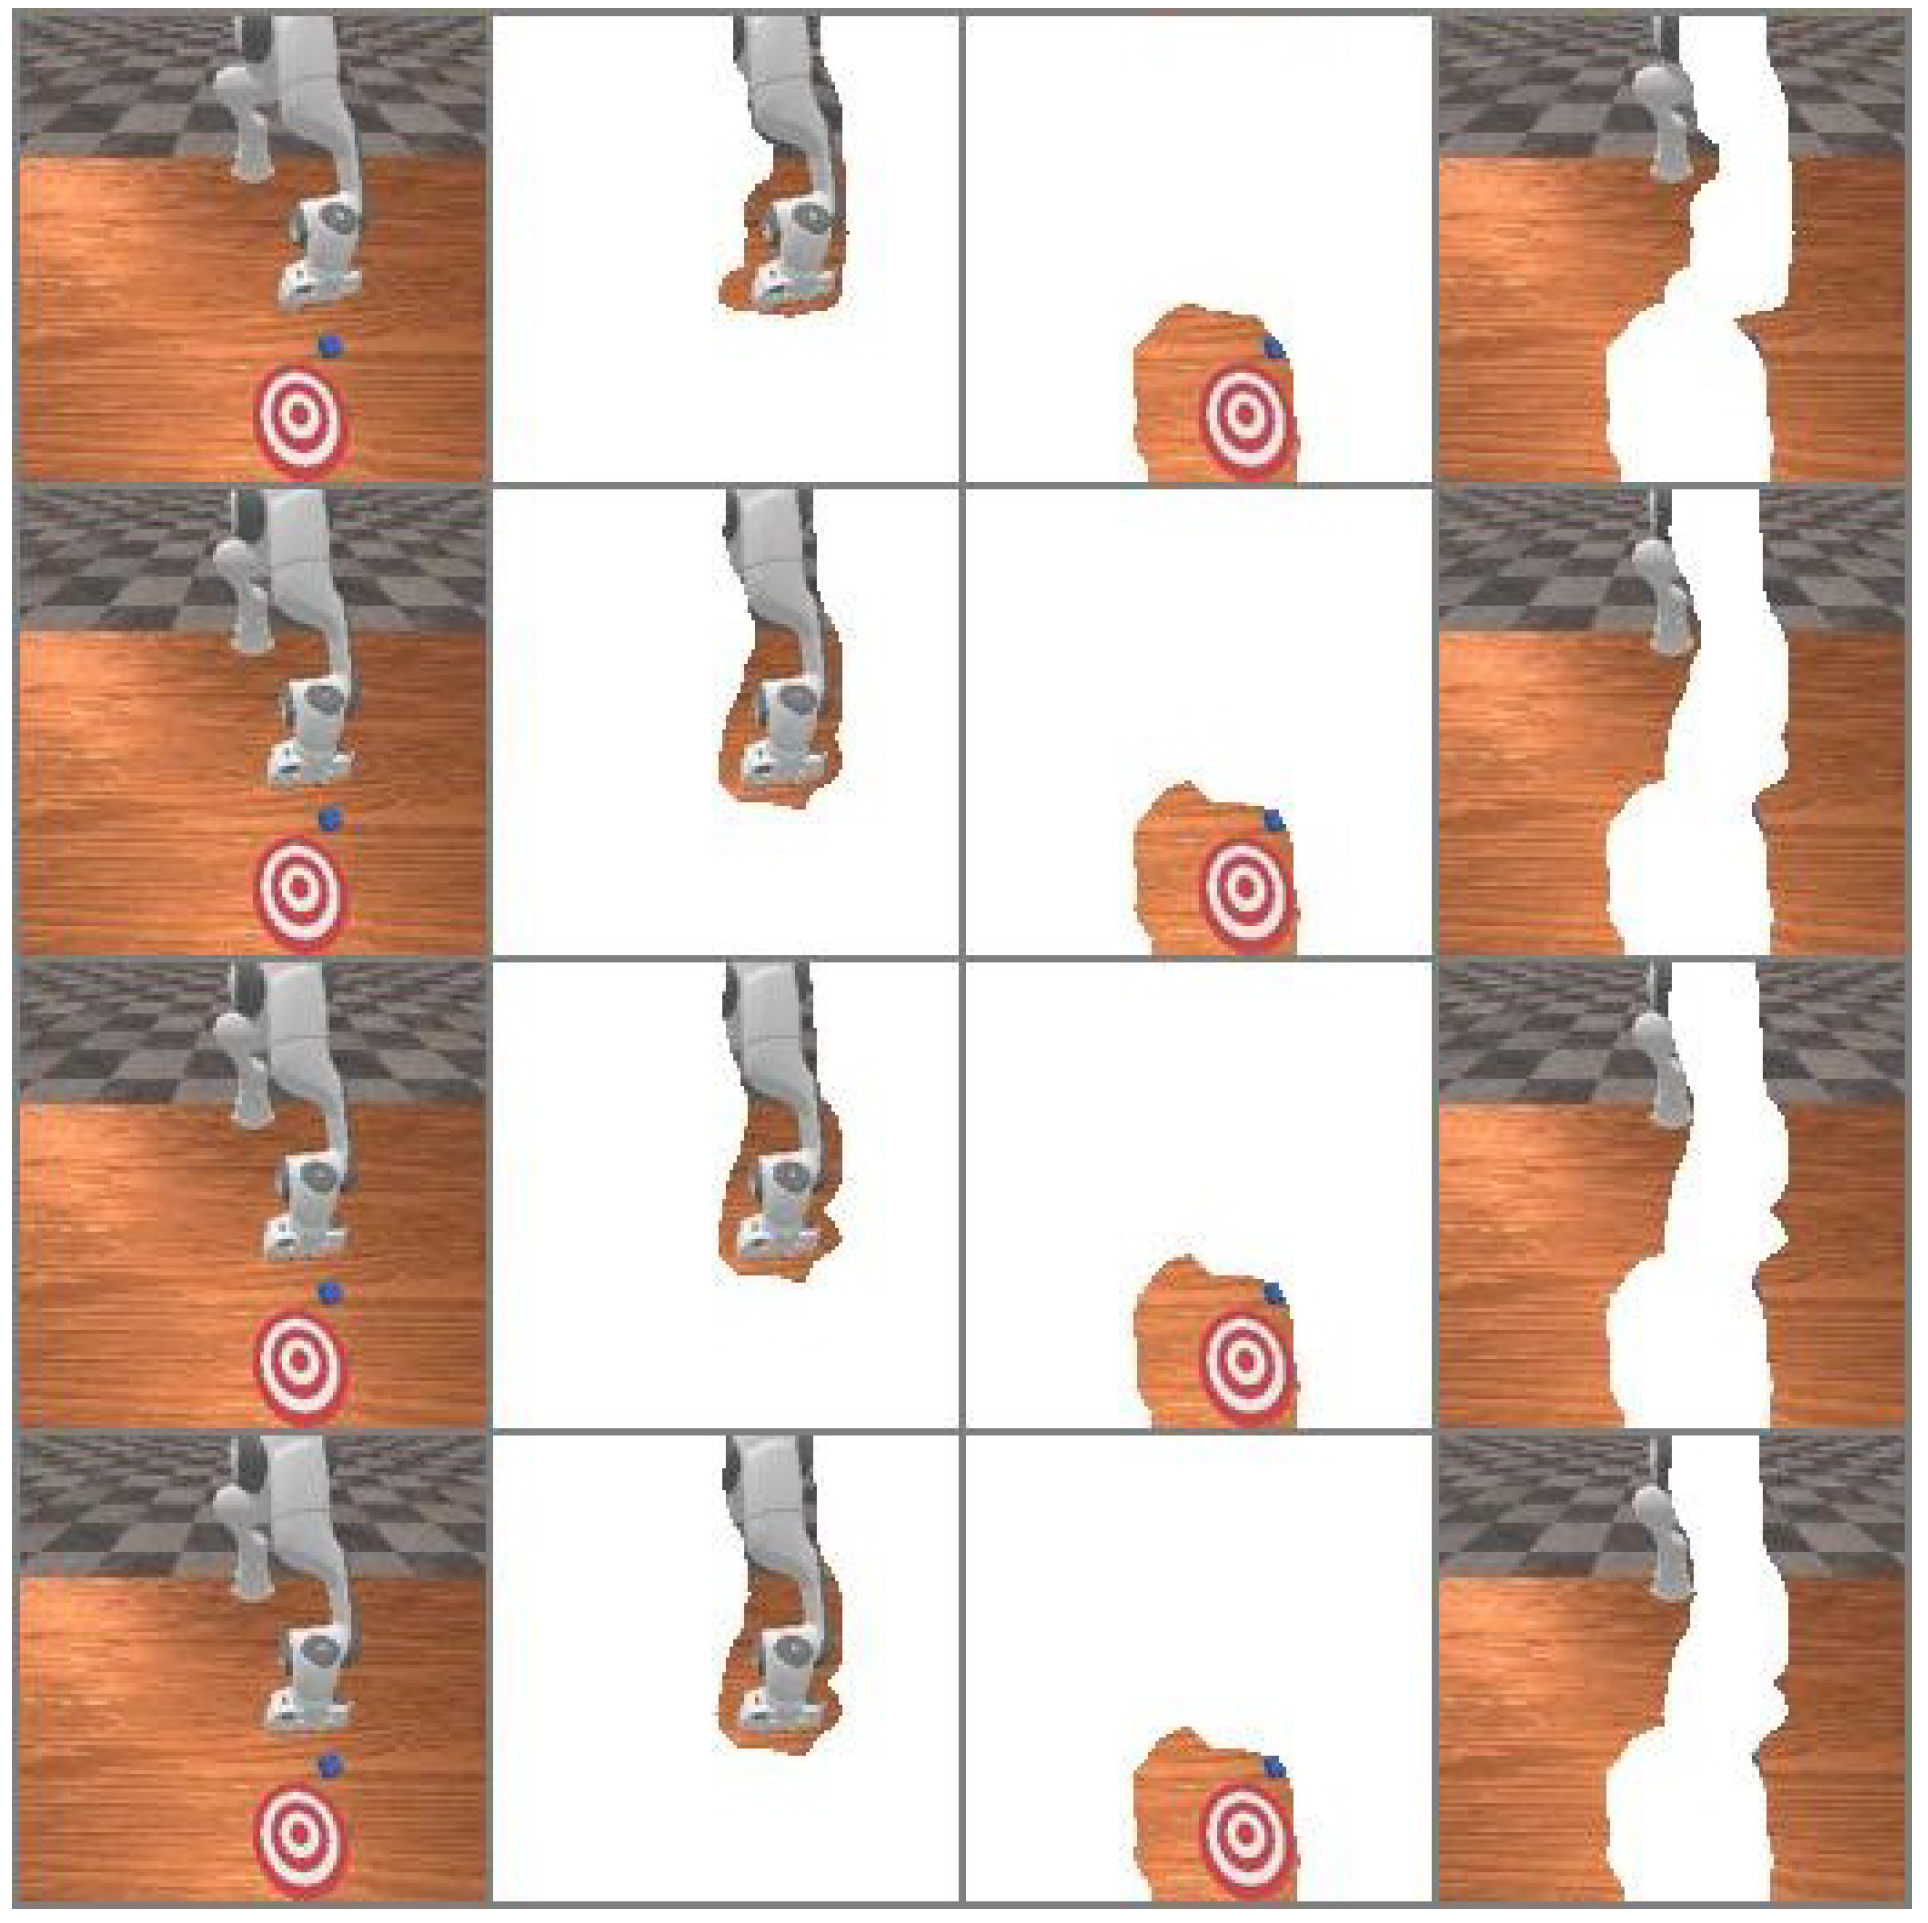
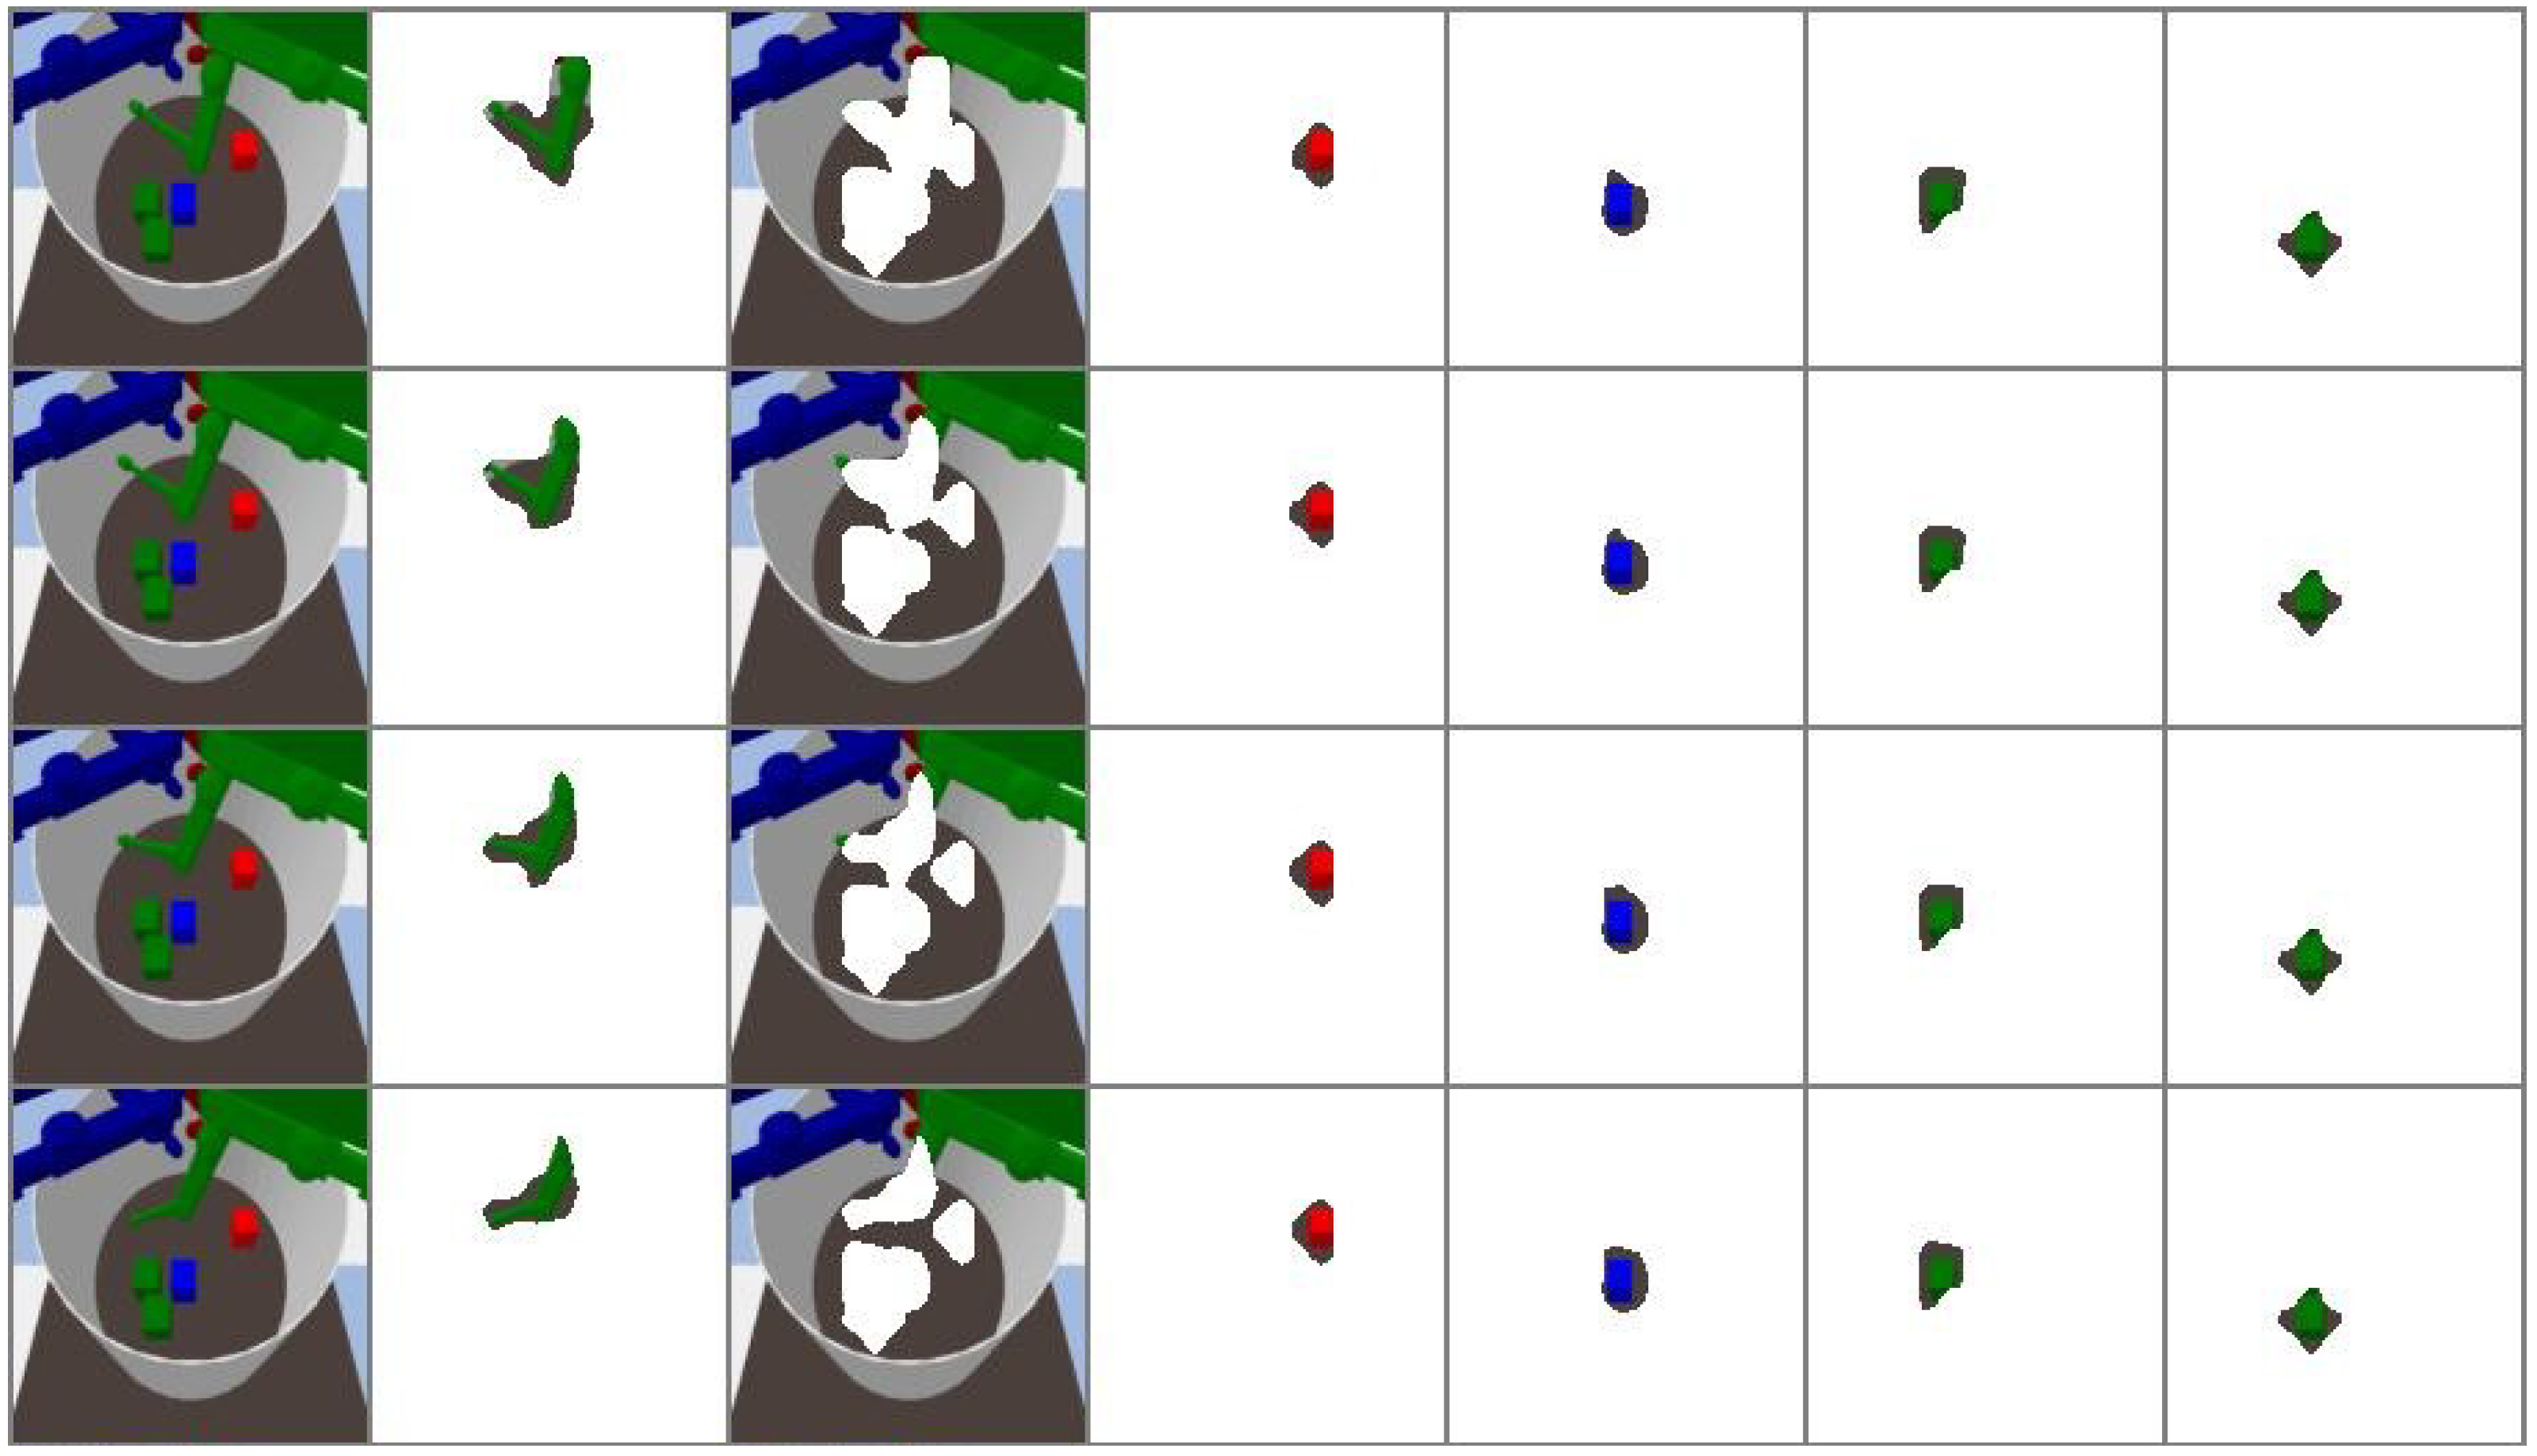
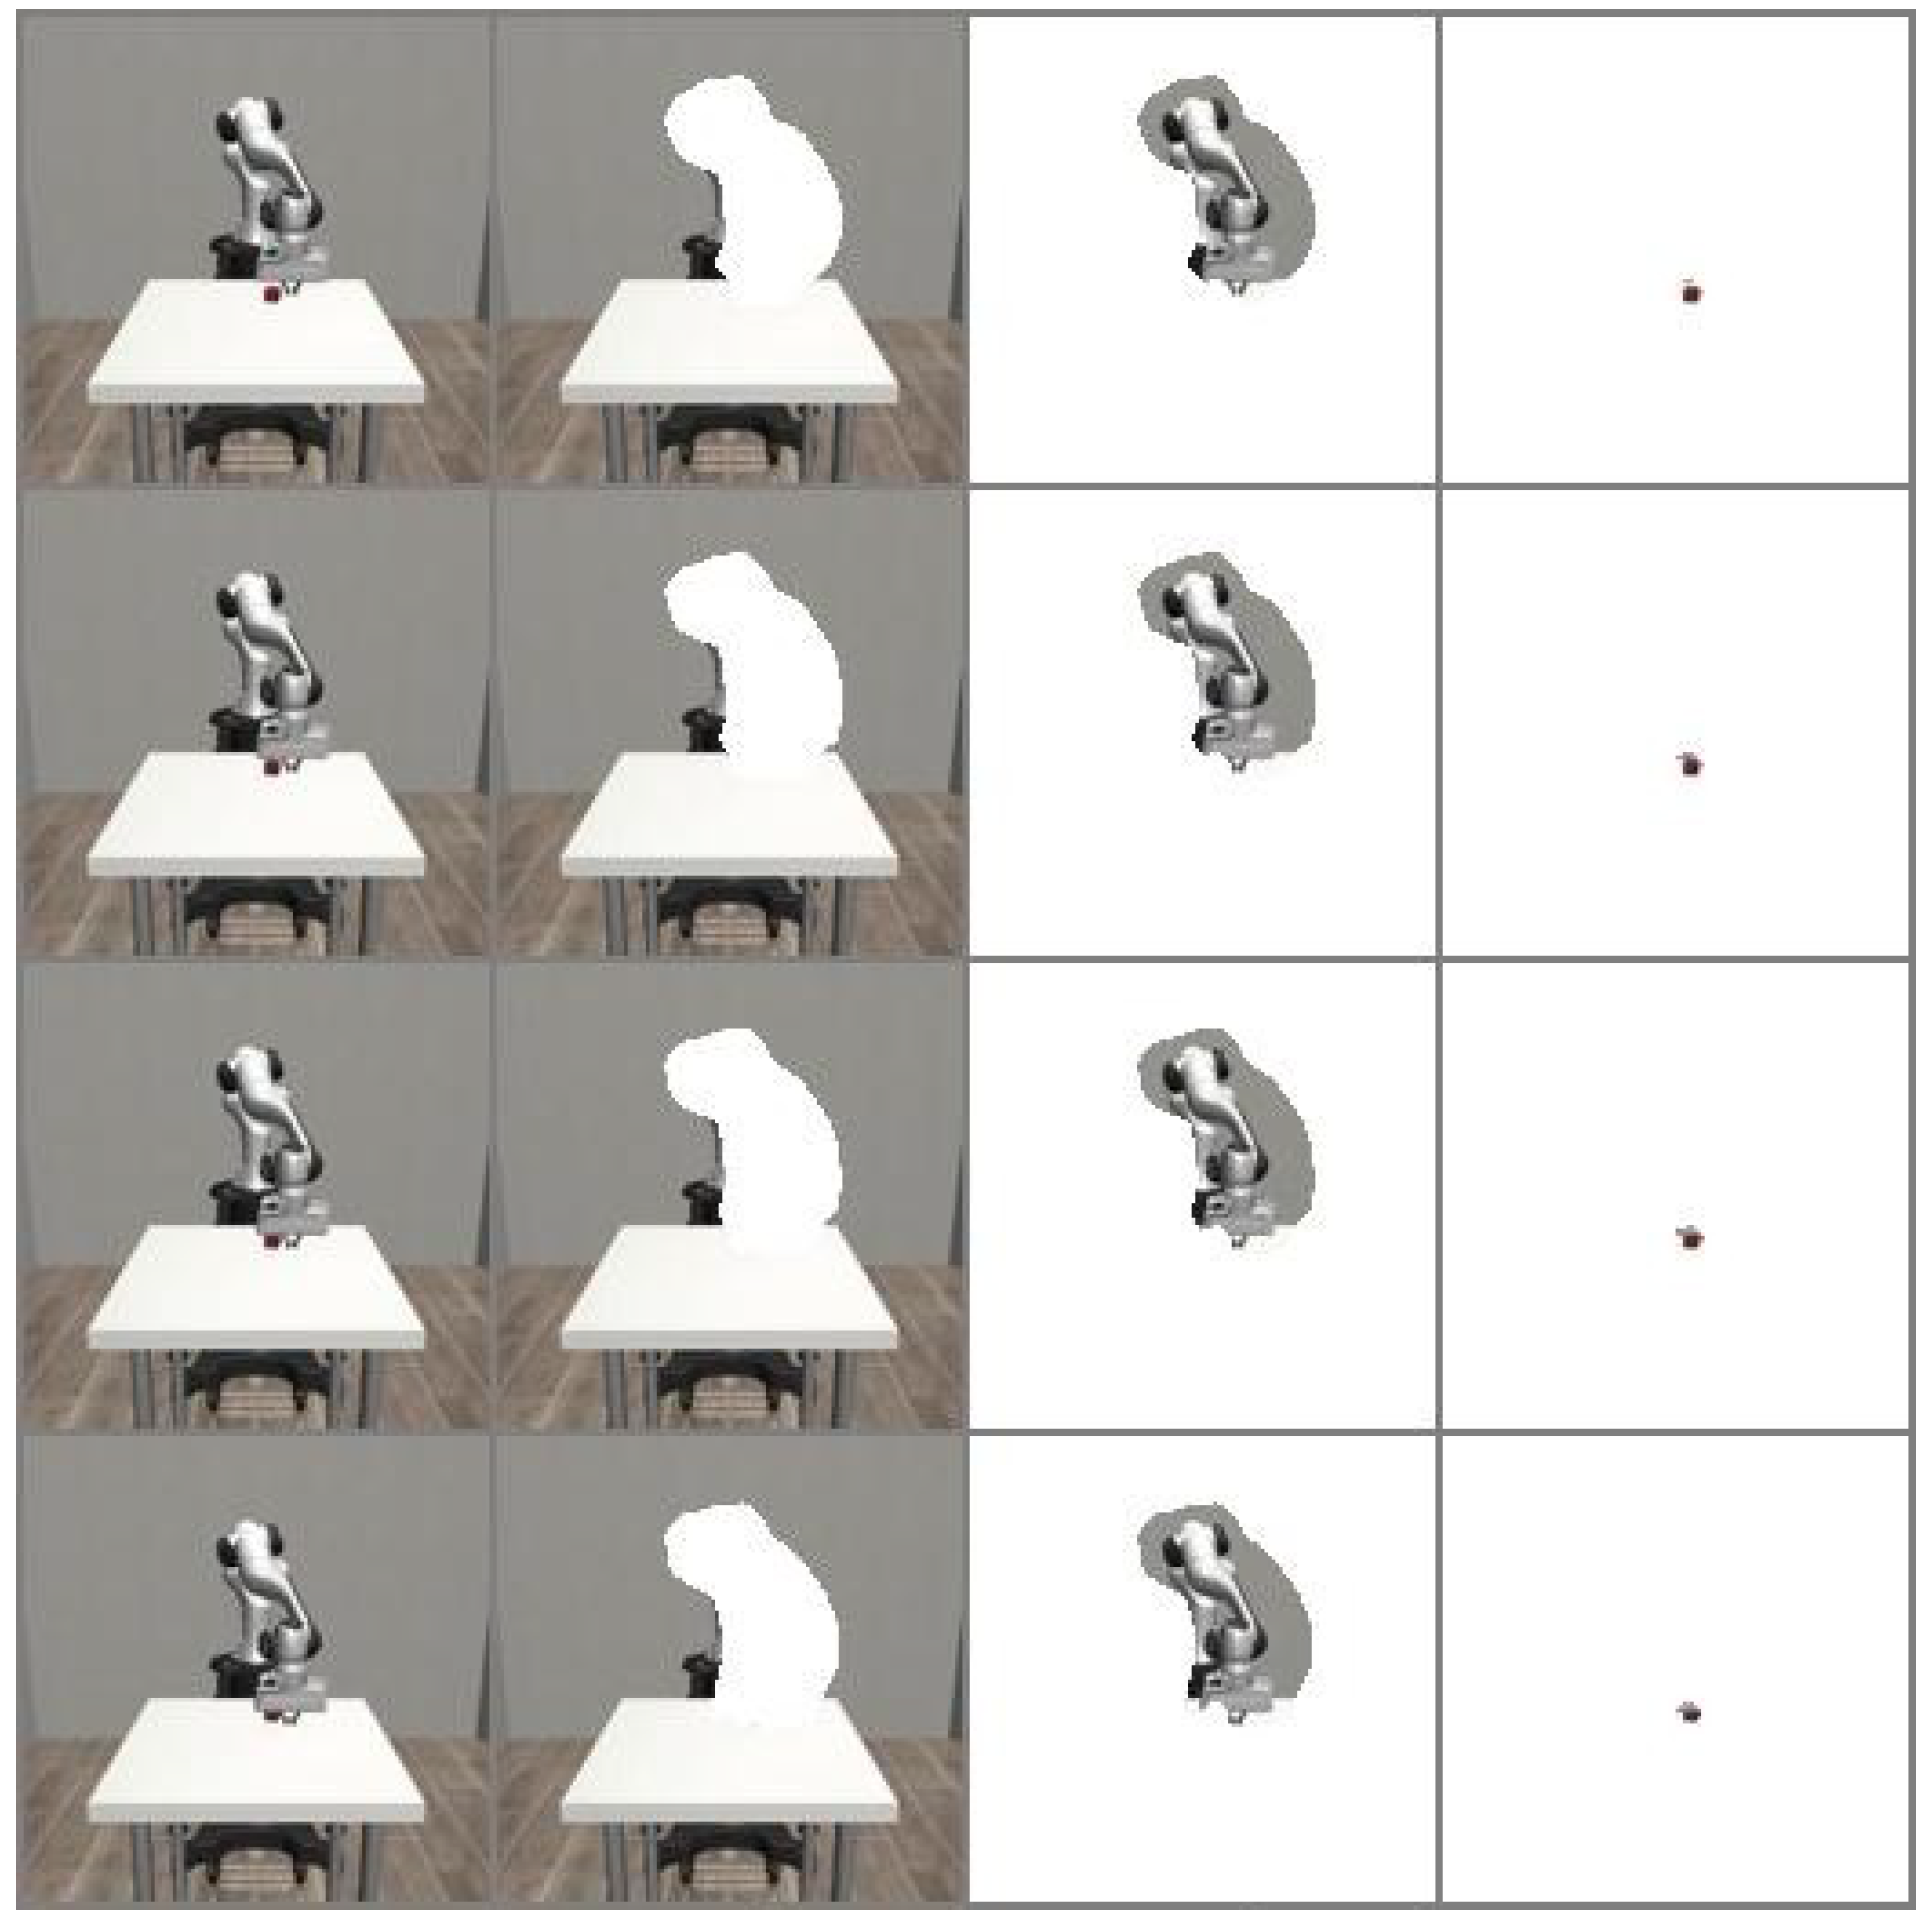
Model-based reinforcement learning (MBRL) is a promising approach for achieving high sample efficiency in learning control policies. The existing world models in MBRL typically represent the environment’s state as a single global latent vector. However, such representations limit the model’s ability to capture object interactions and reason about individual objects—capabilities that are critical for visual object-oriented tasks—and may lead to lower sample efficiency. To address this limitation, we propose Kuramoto Object-Centric Reinforcement Learning (KORL), a model-based agent that learns an object-centric world model. Our approach introduces a novel Kuramoto Slot Attention for Video (KSAVi) model that integrates Kuramoto oscillatory neurons with the Slot Attention module to robustly extract object representations. We design a world model that leverages these structured object-centric latents and predicts dynamics using graph neural networks, thereby incorporating an inductive bias for modeling object interactions. We evaluate KORL on a suite of visually diverse object-oriented robotic manipulation tasks and demonstrate that our method outperforms object-centric model-free and model-based approaches.
Keywords: reinforcement learning; world model; model predictive control; object-centric representation reinforcement learning; world model; model predictive control; object-centric representation