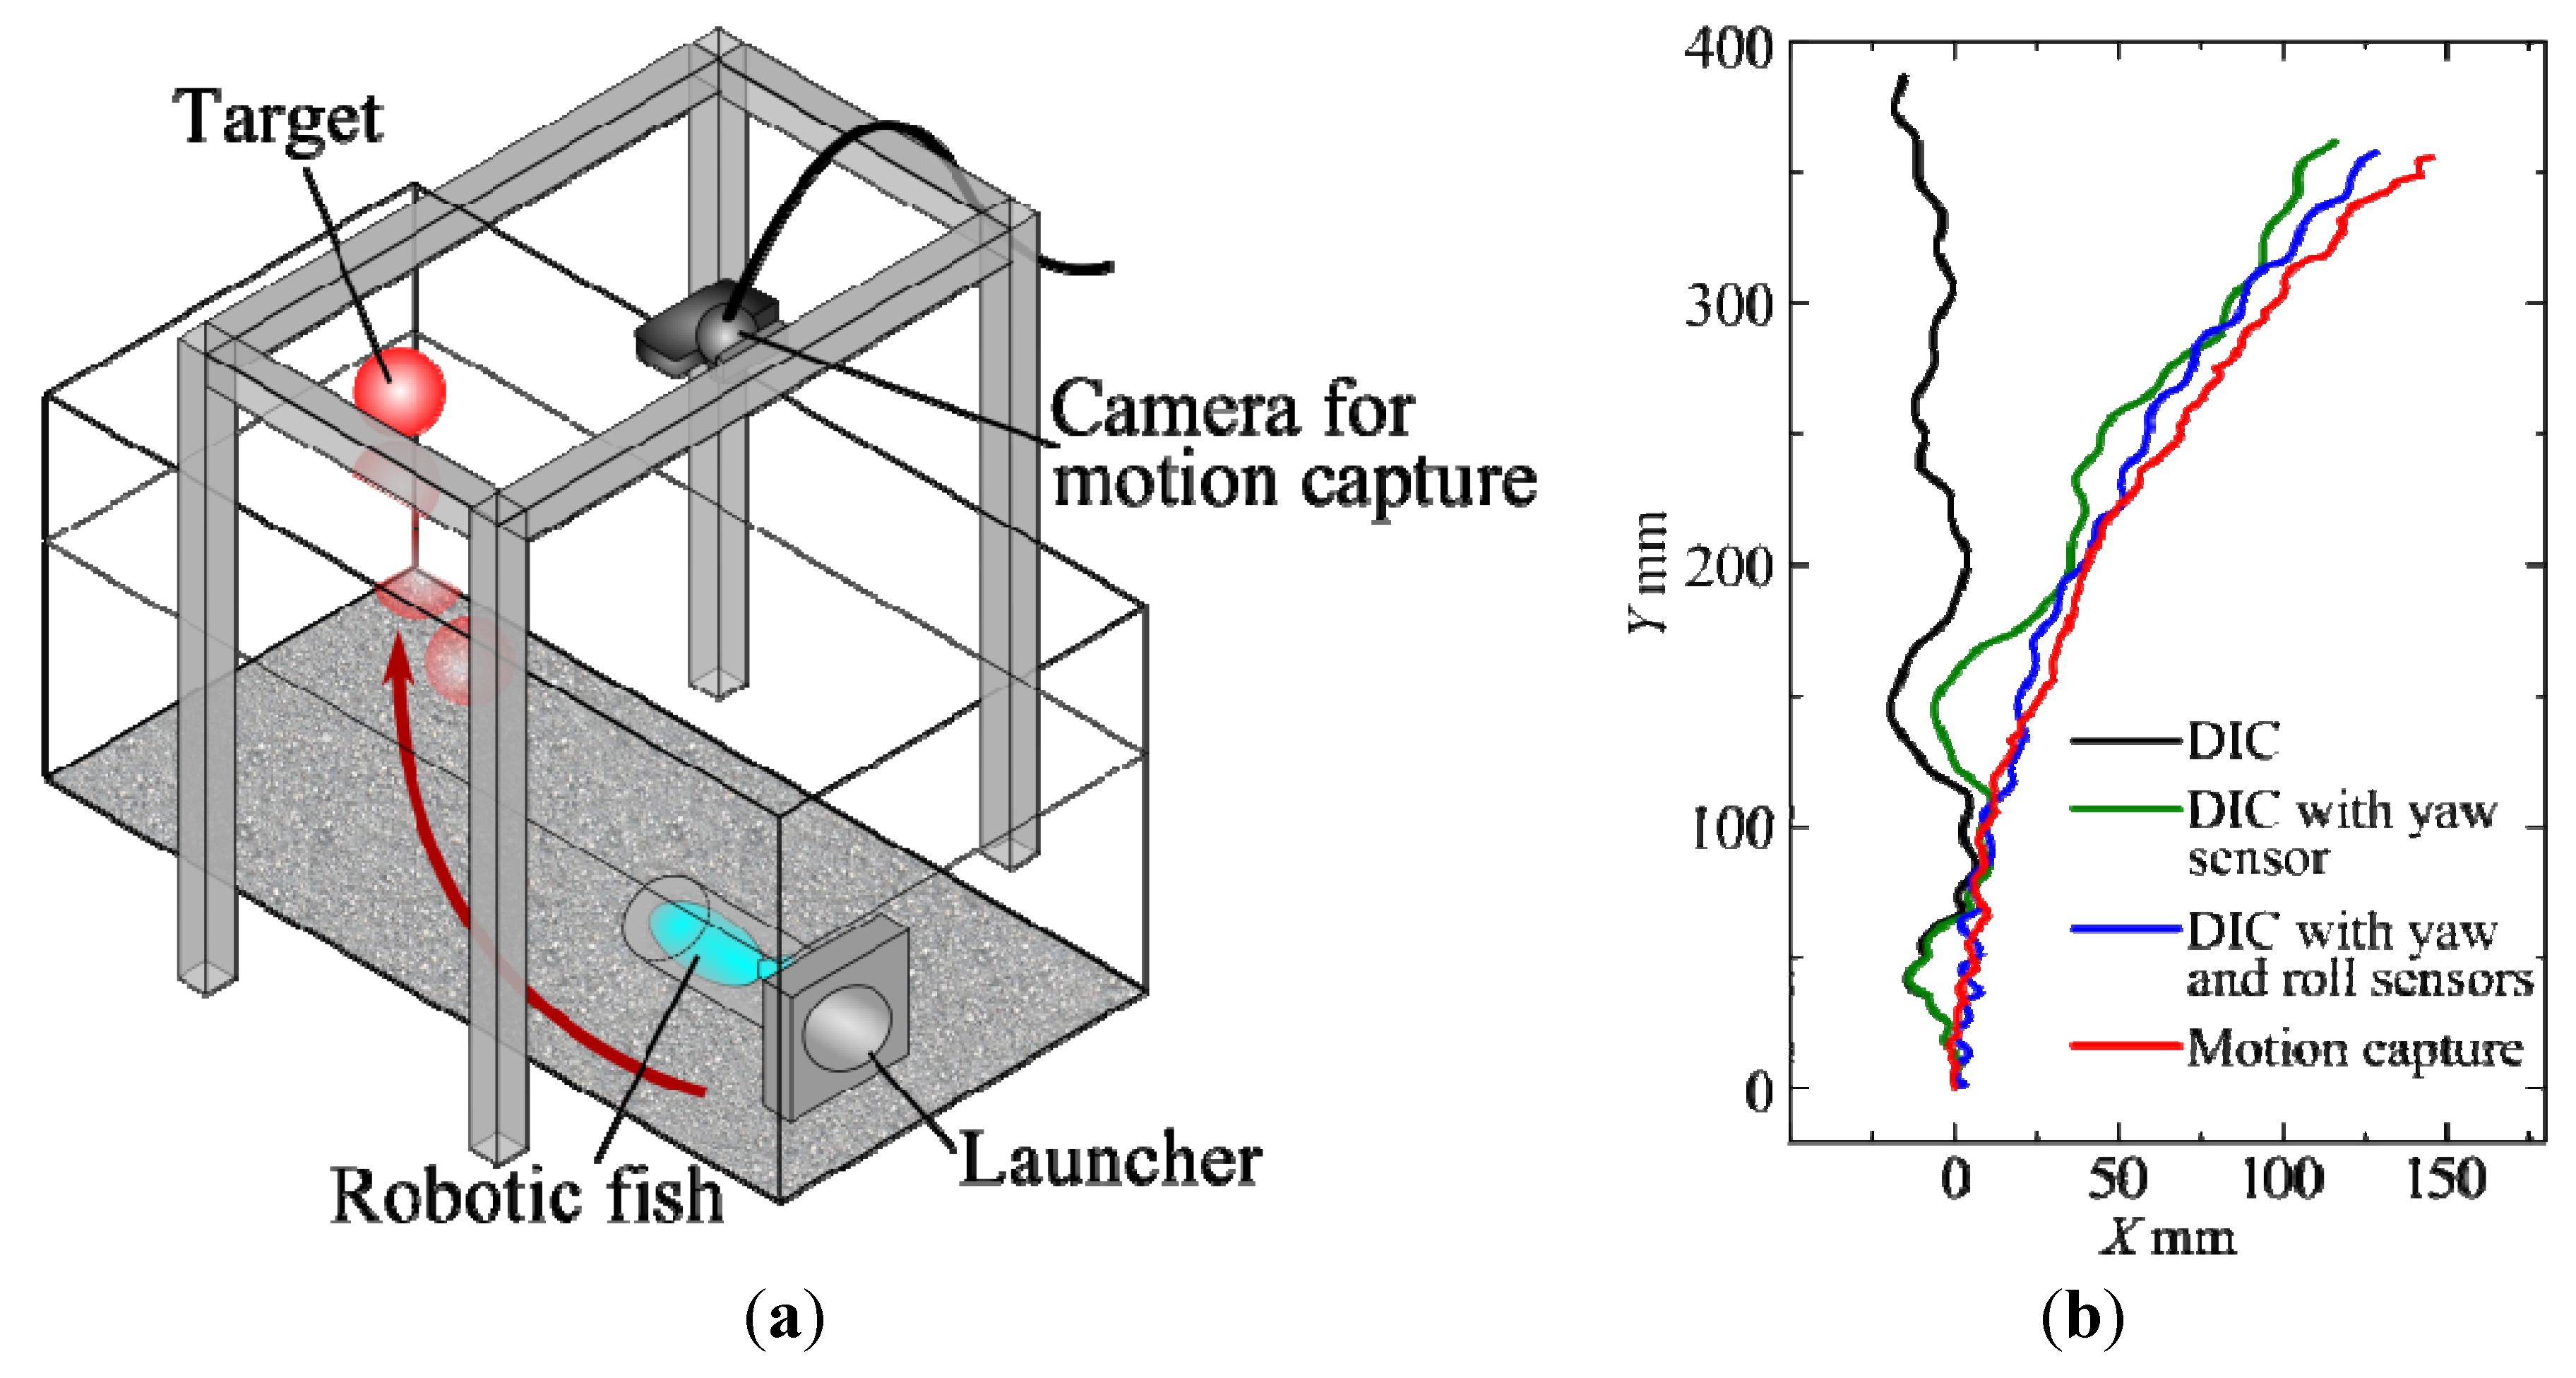
Position Estimation of Small Robotic Fish Based on Camera Information and Gyro Sensors

Abstract
1. Introduction
2. Robotic Fish FOCUS
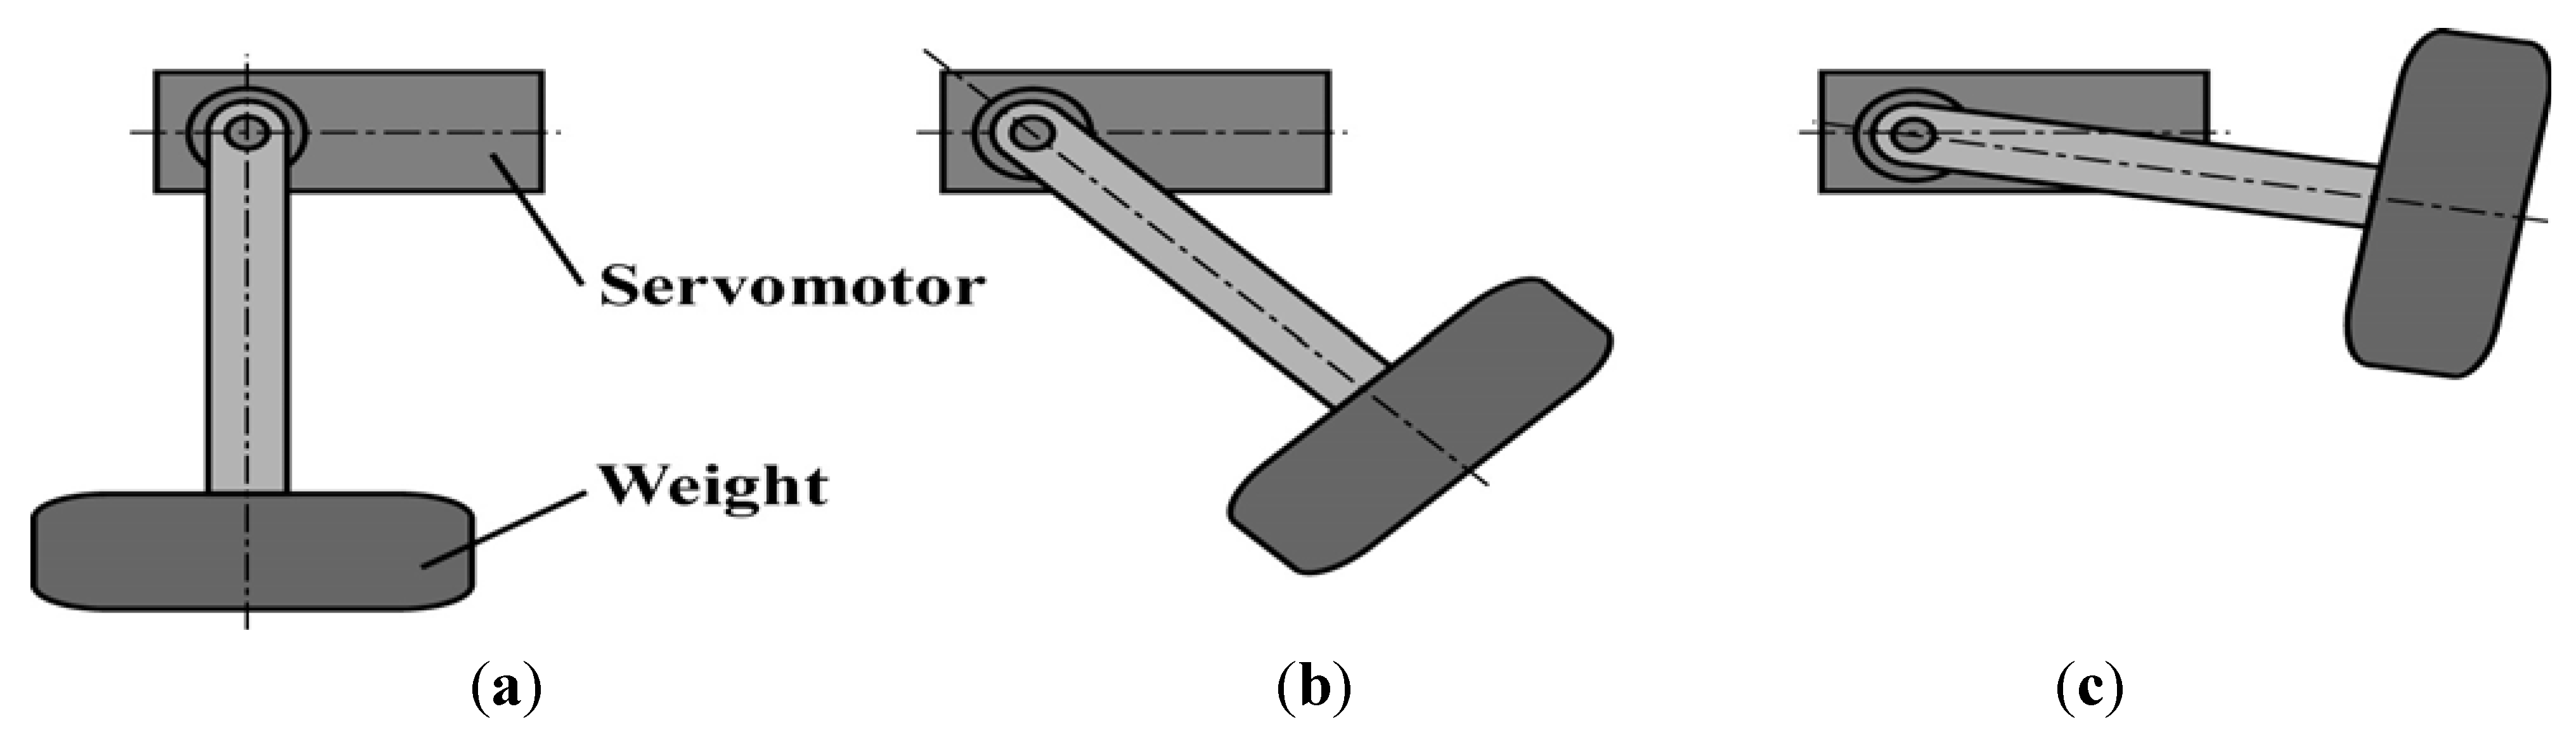
2.1. Structure of FOCUS
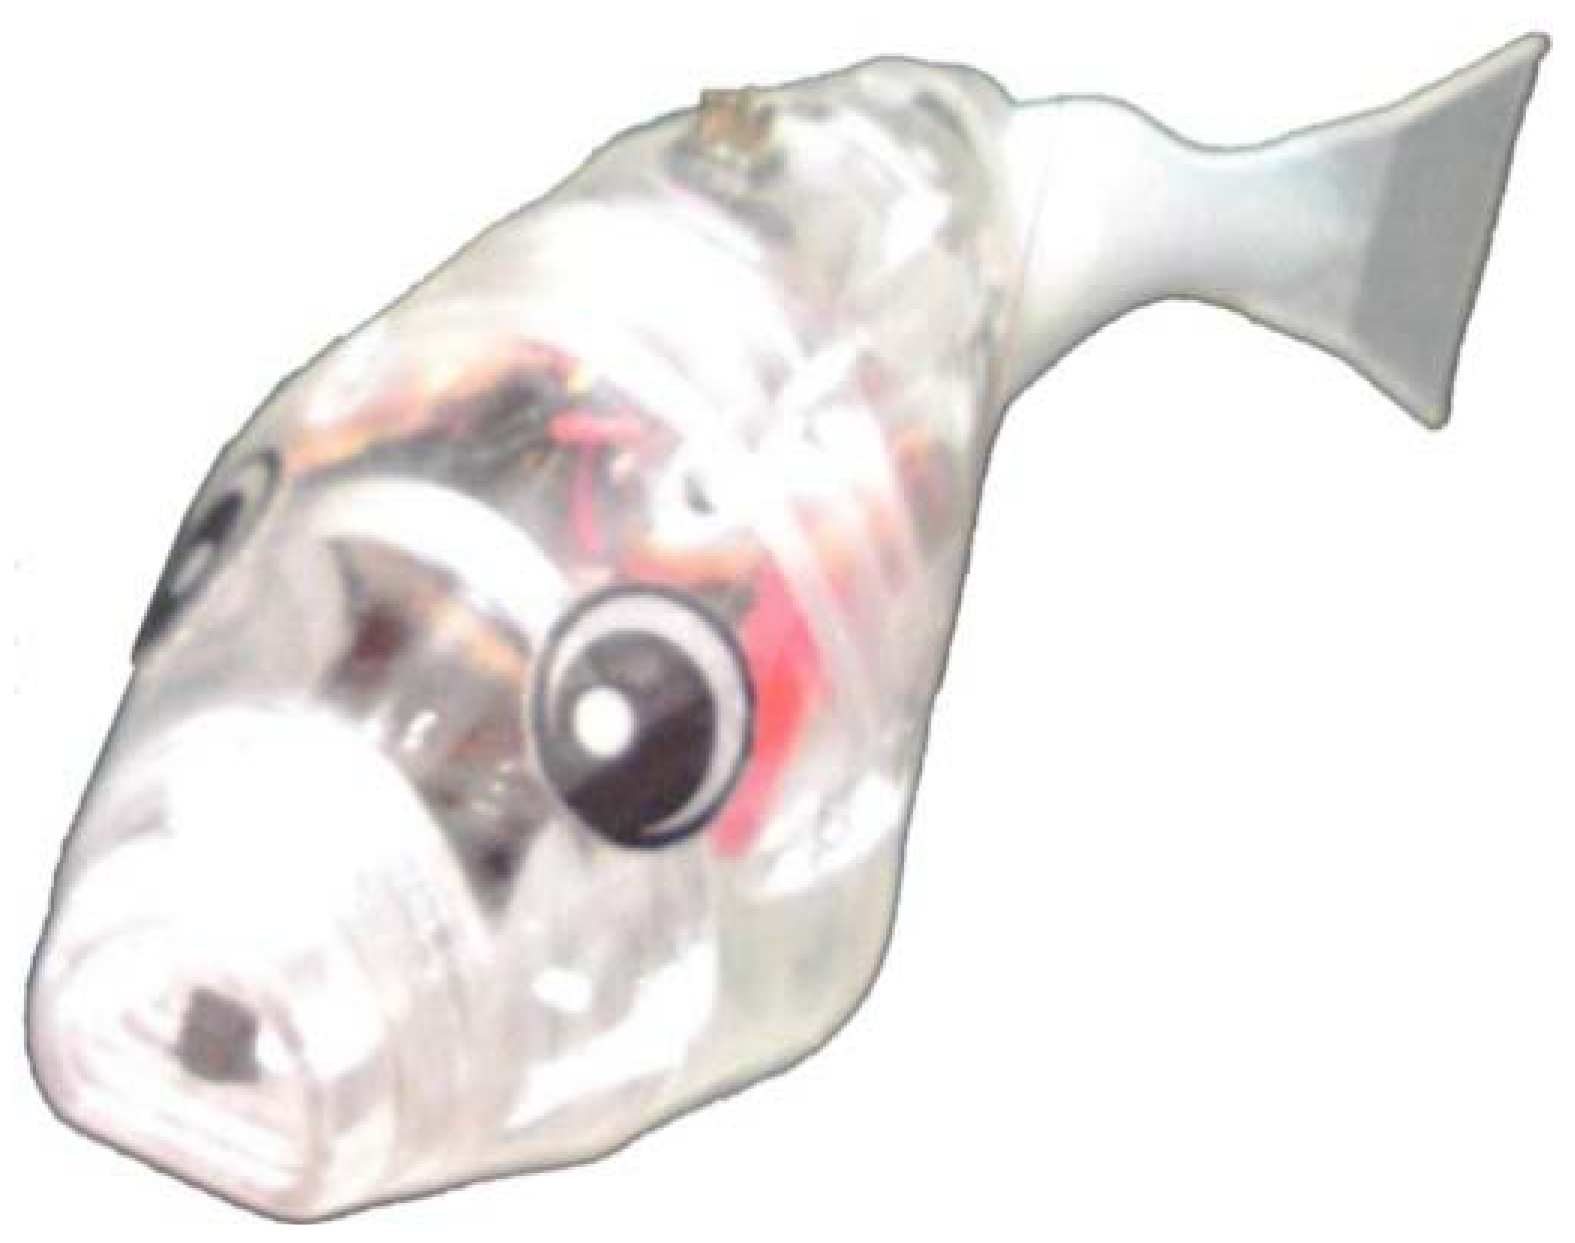
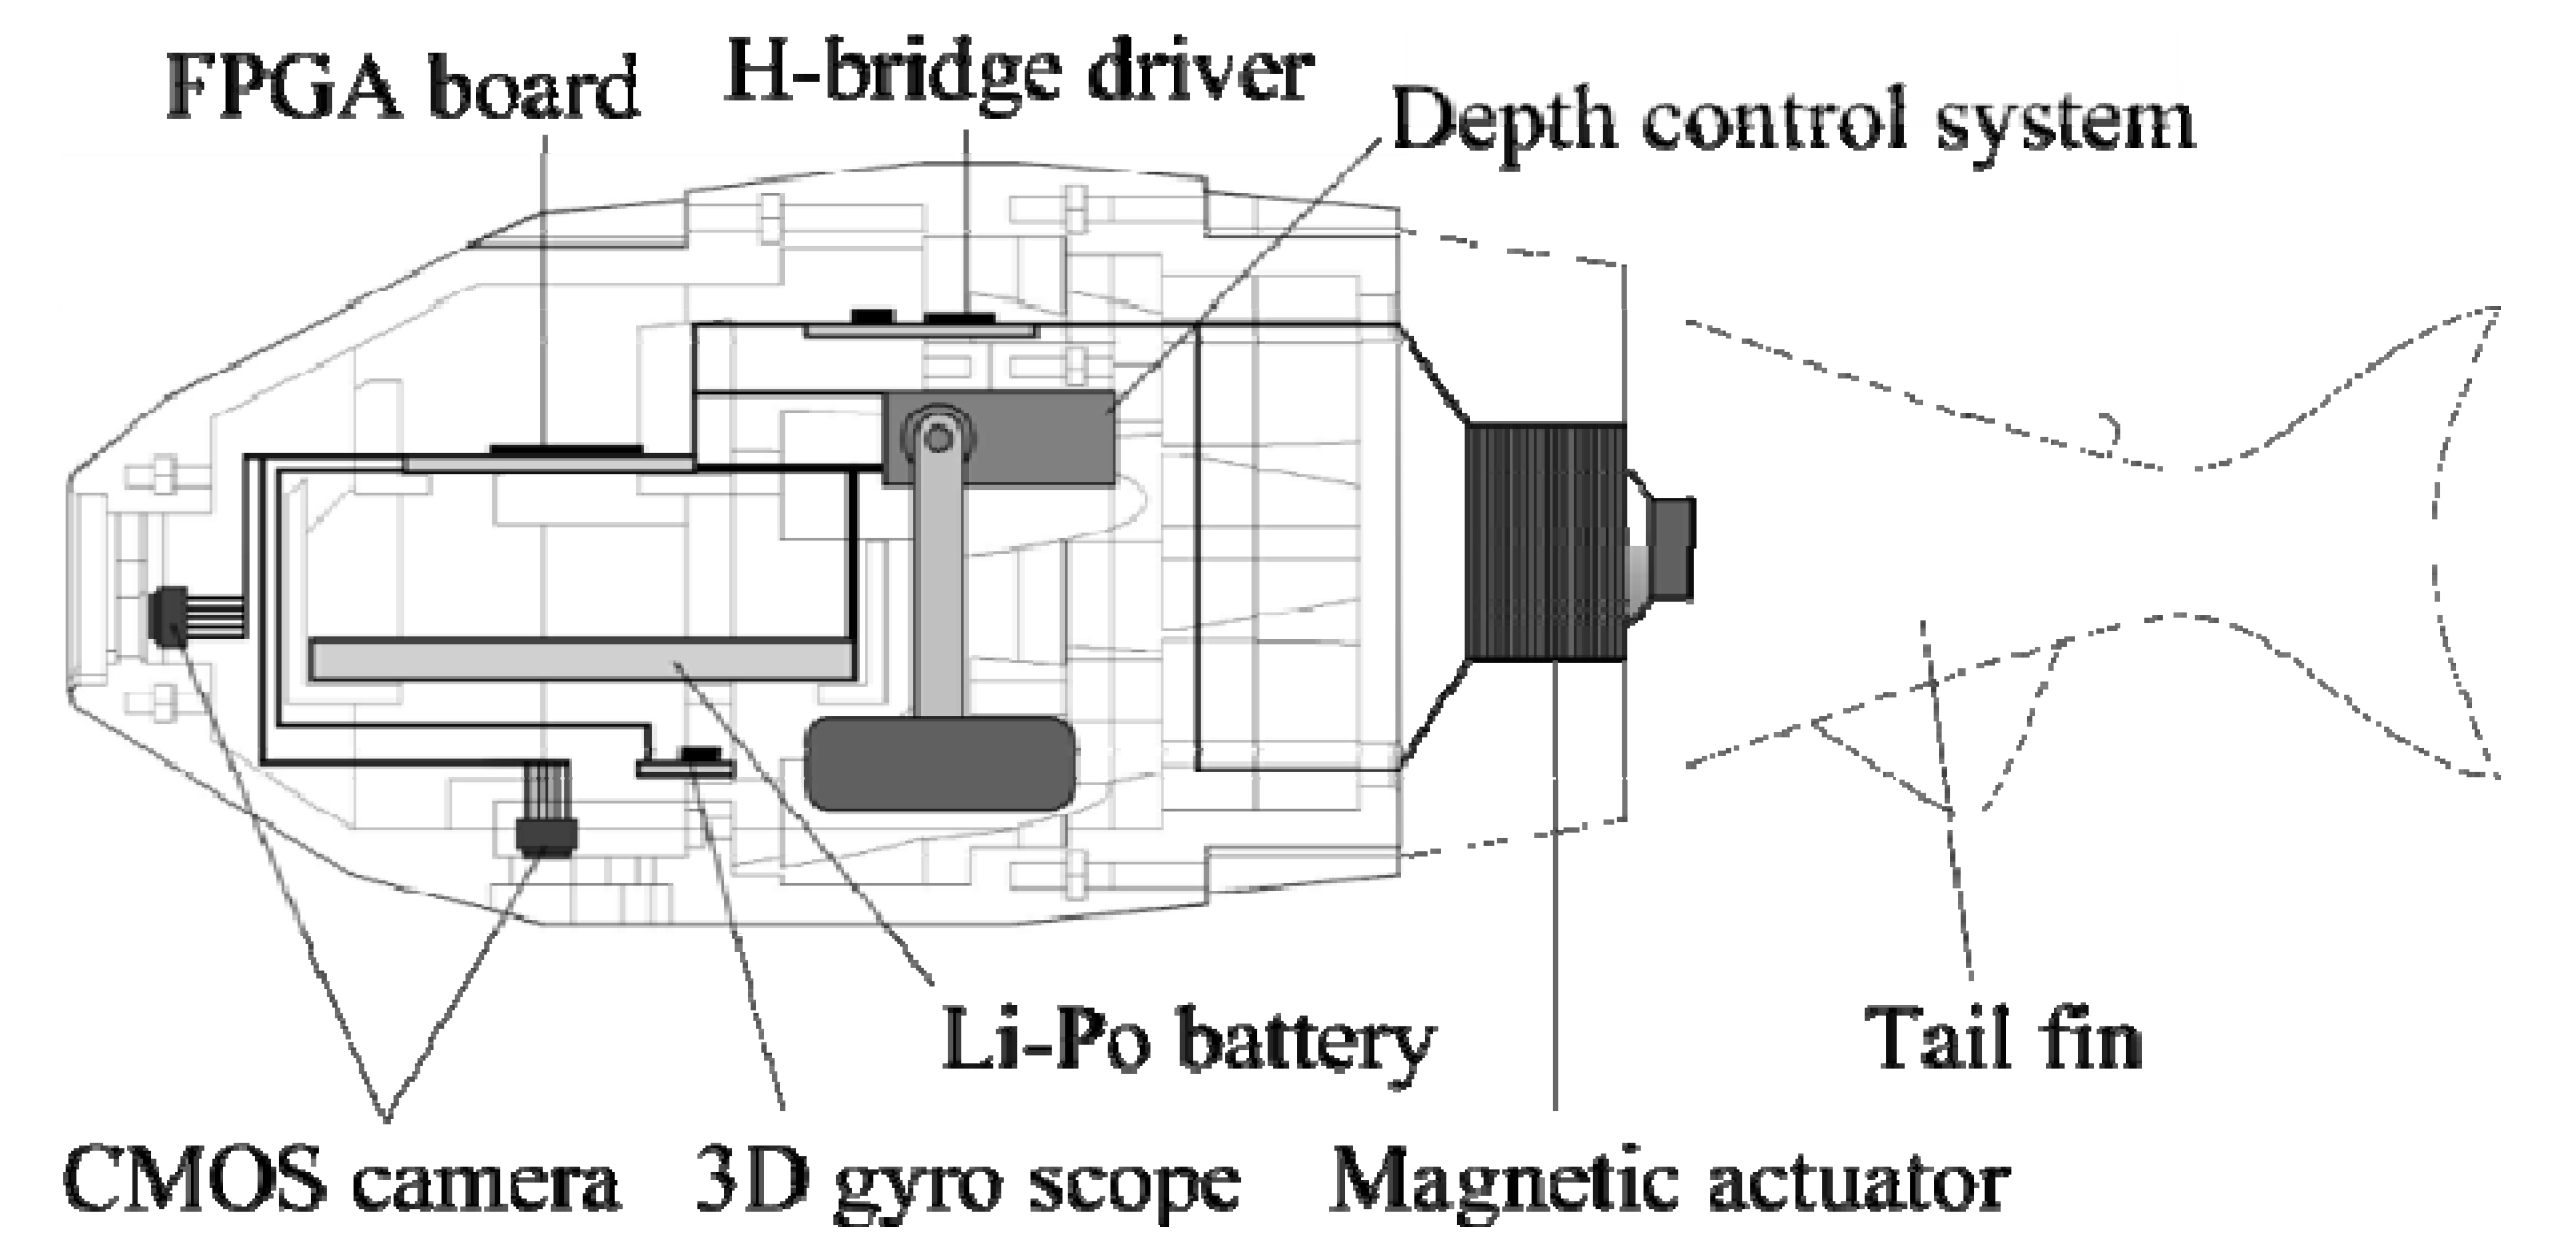
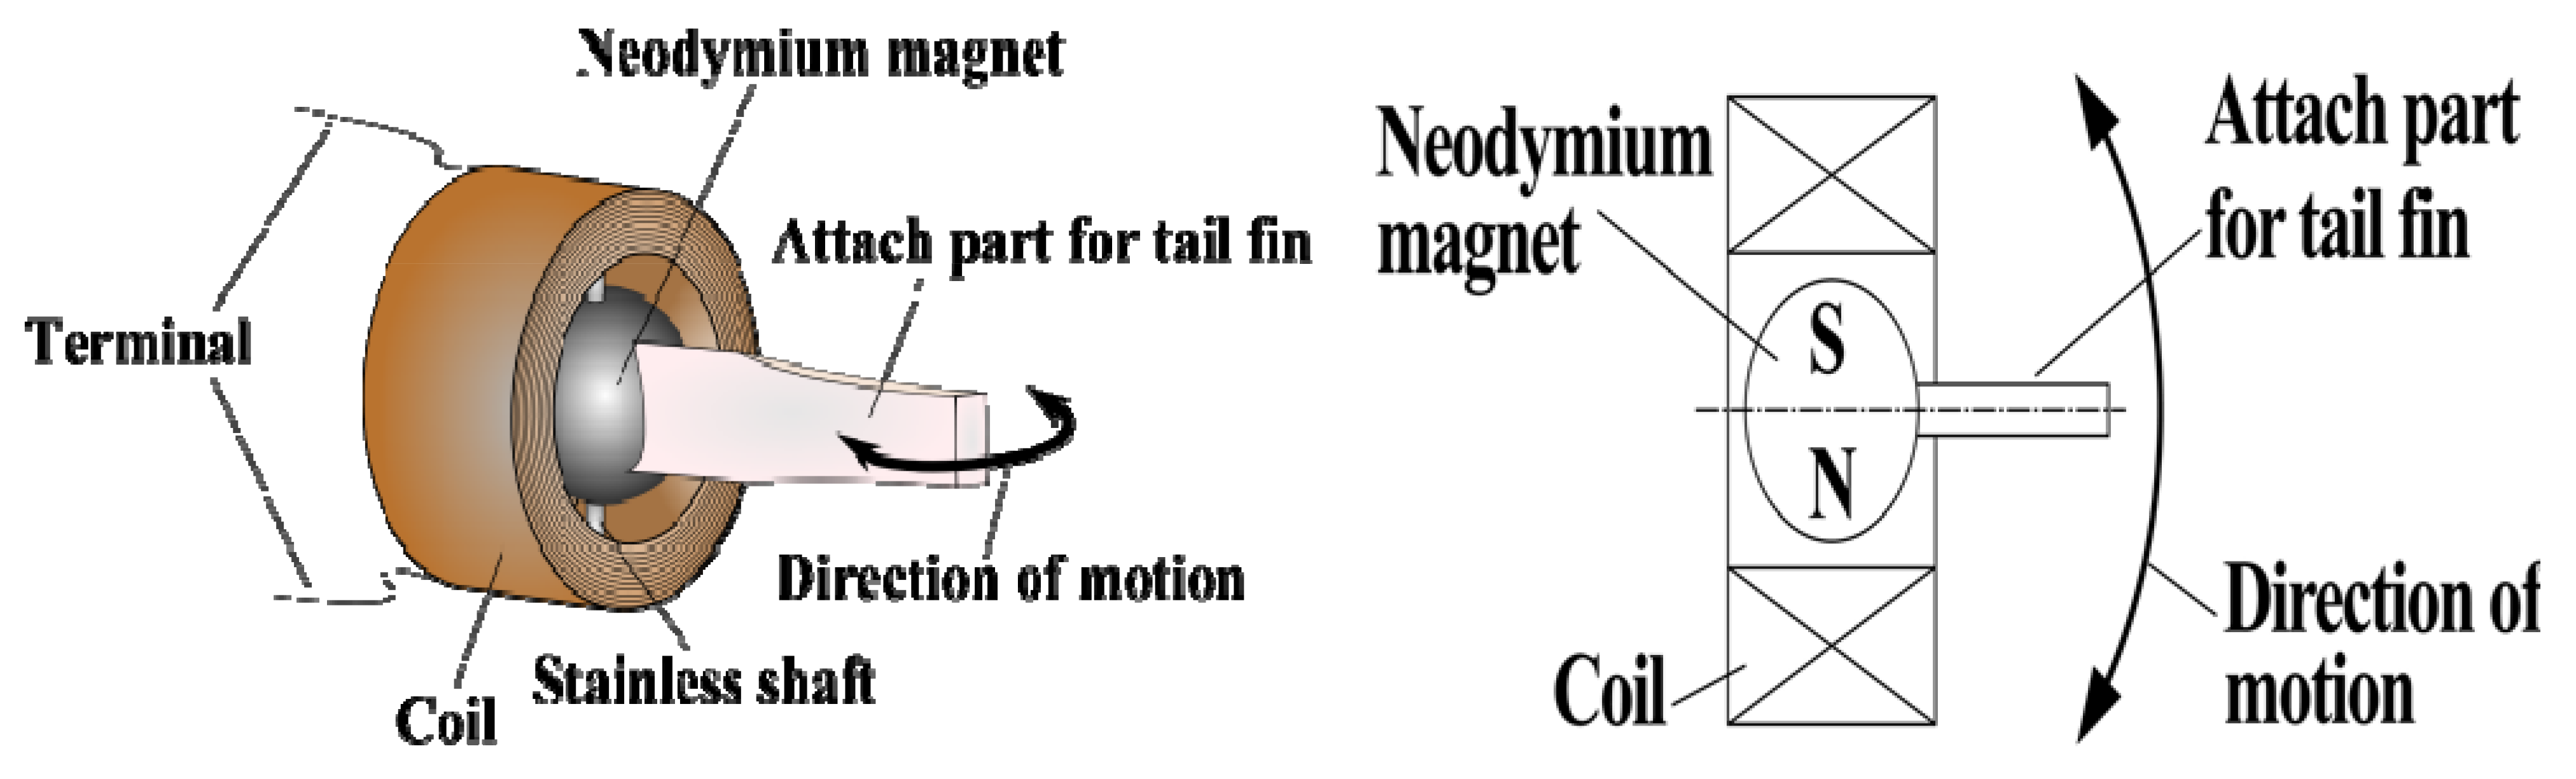
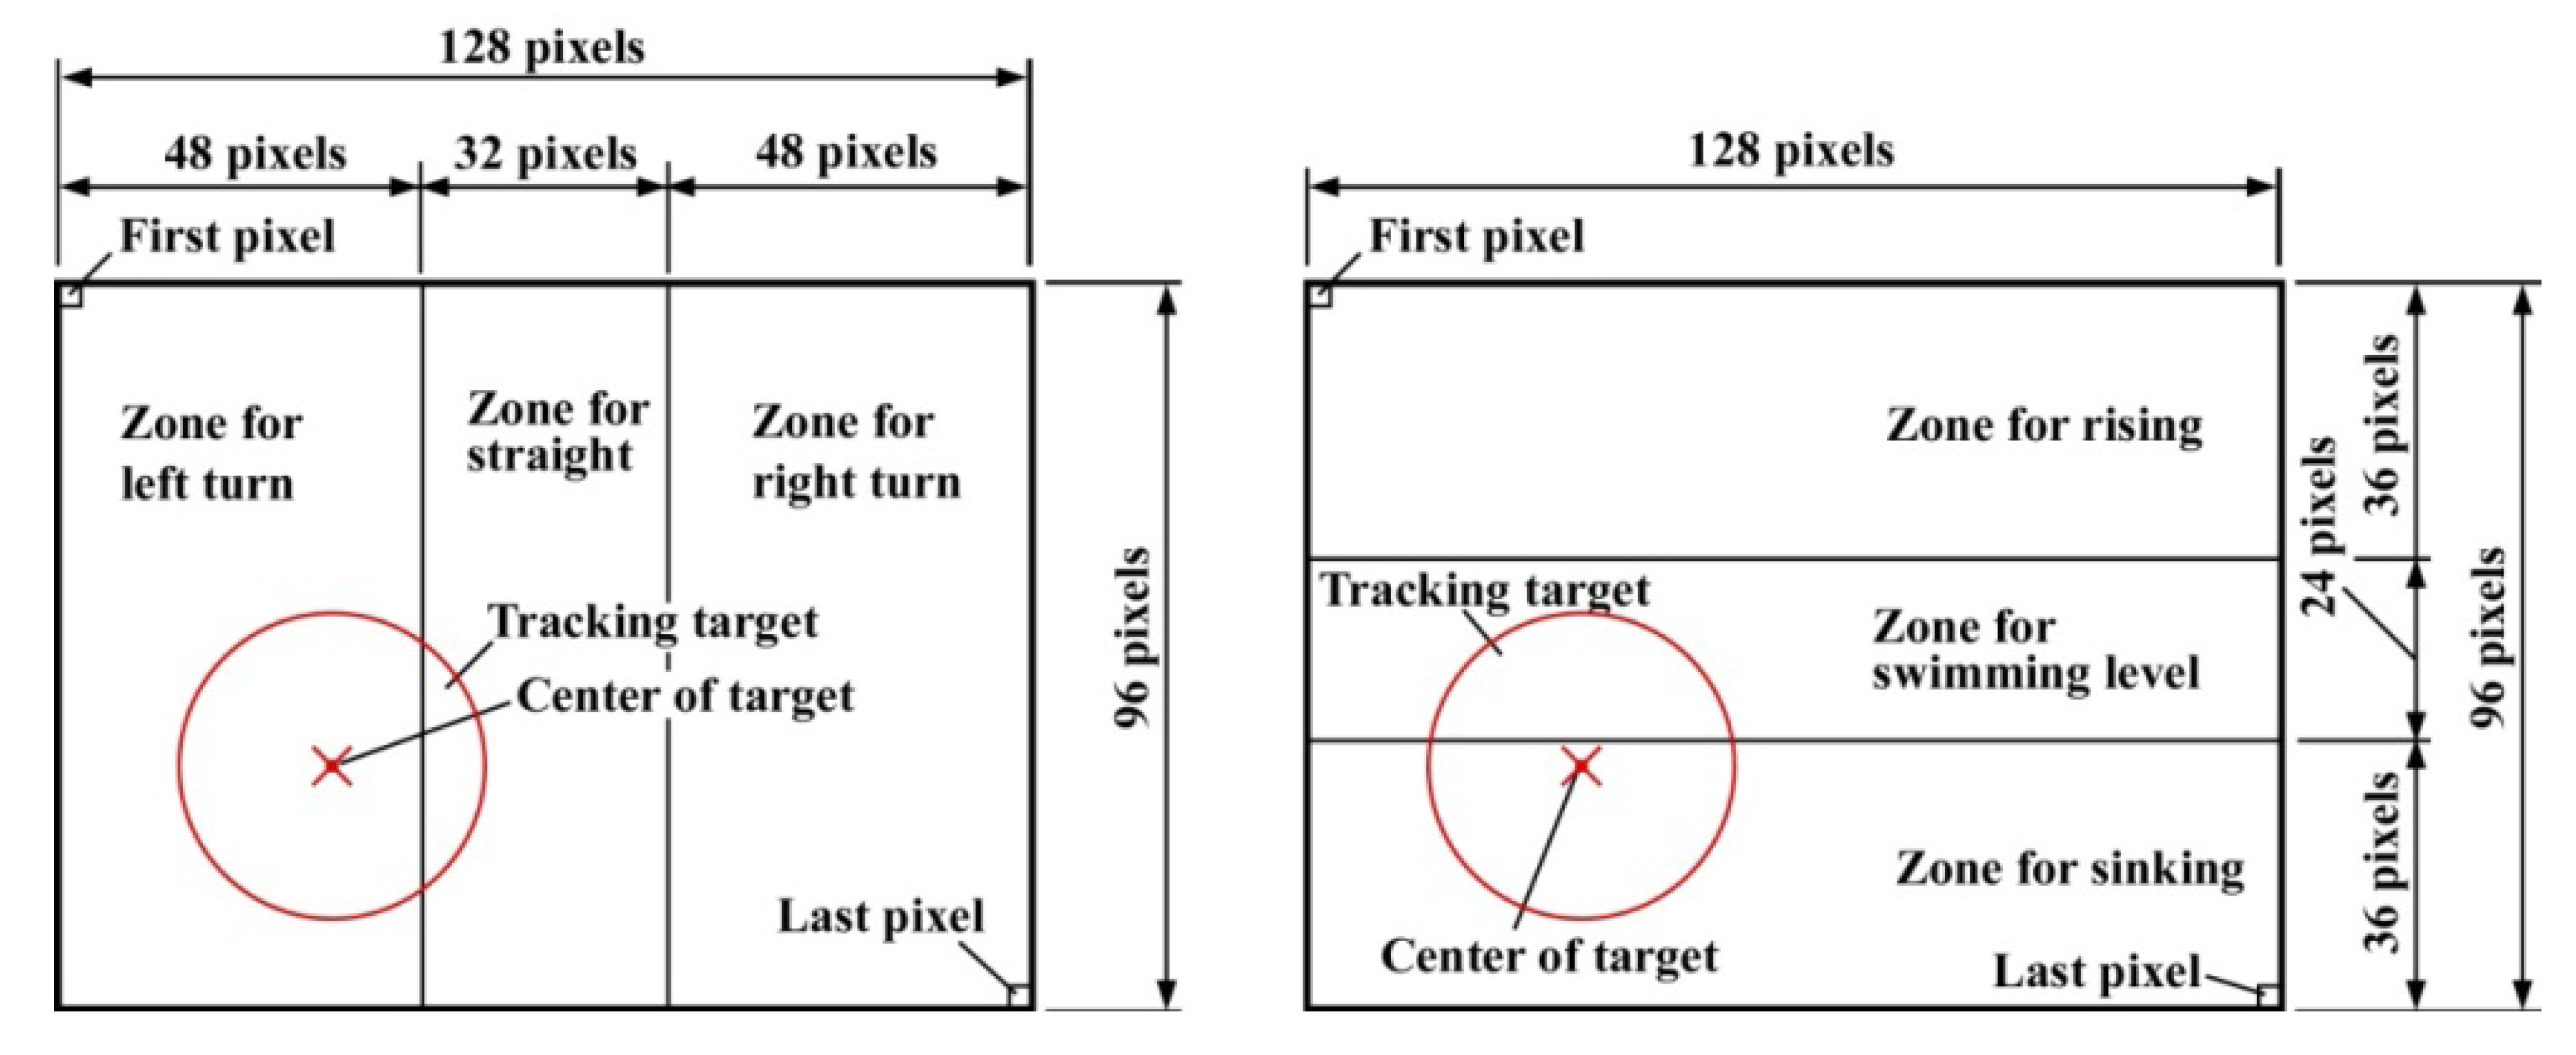
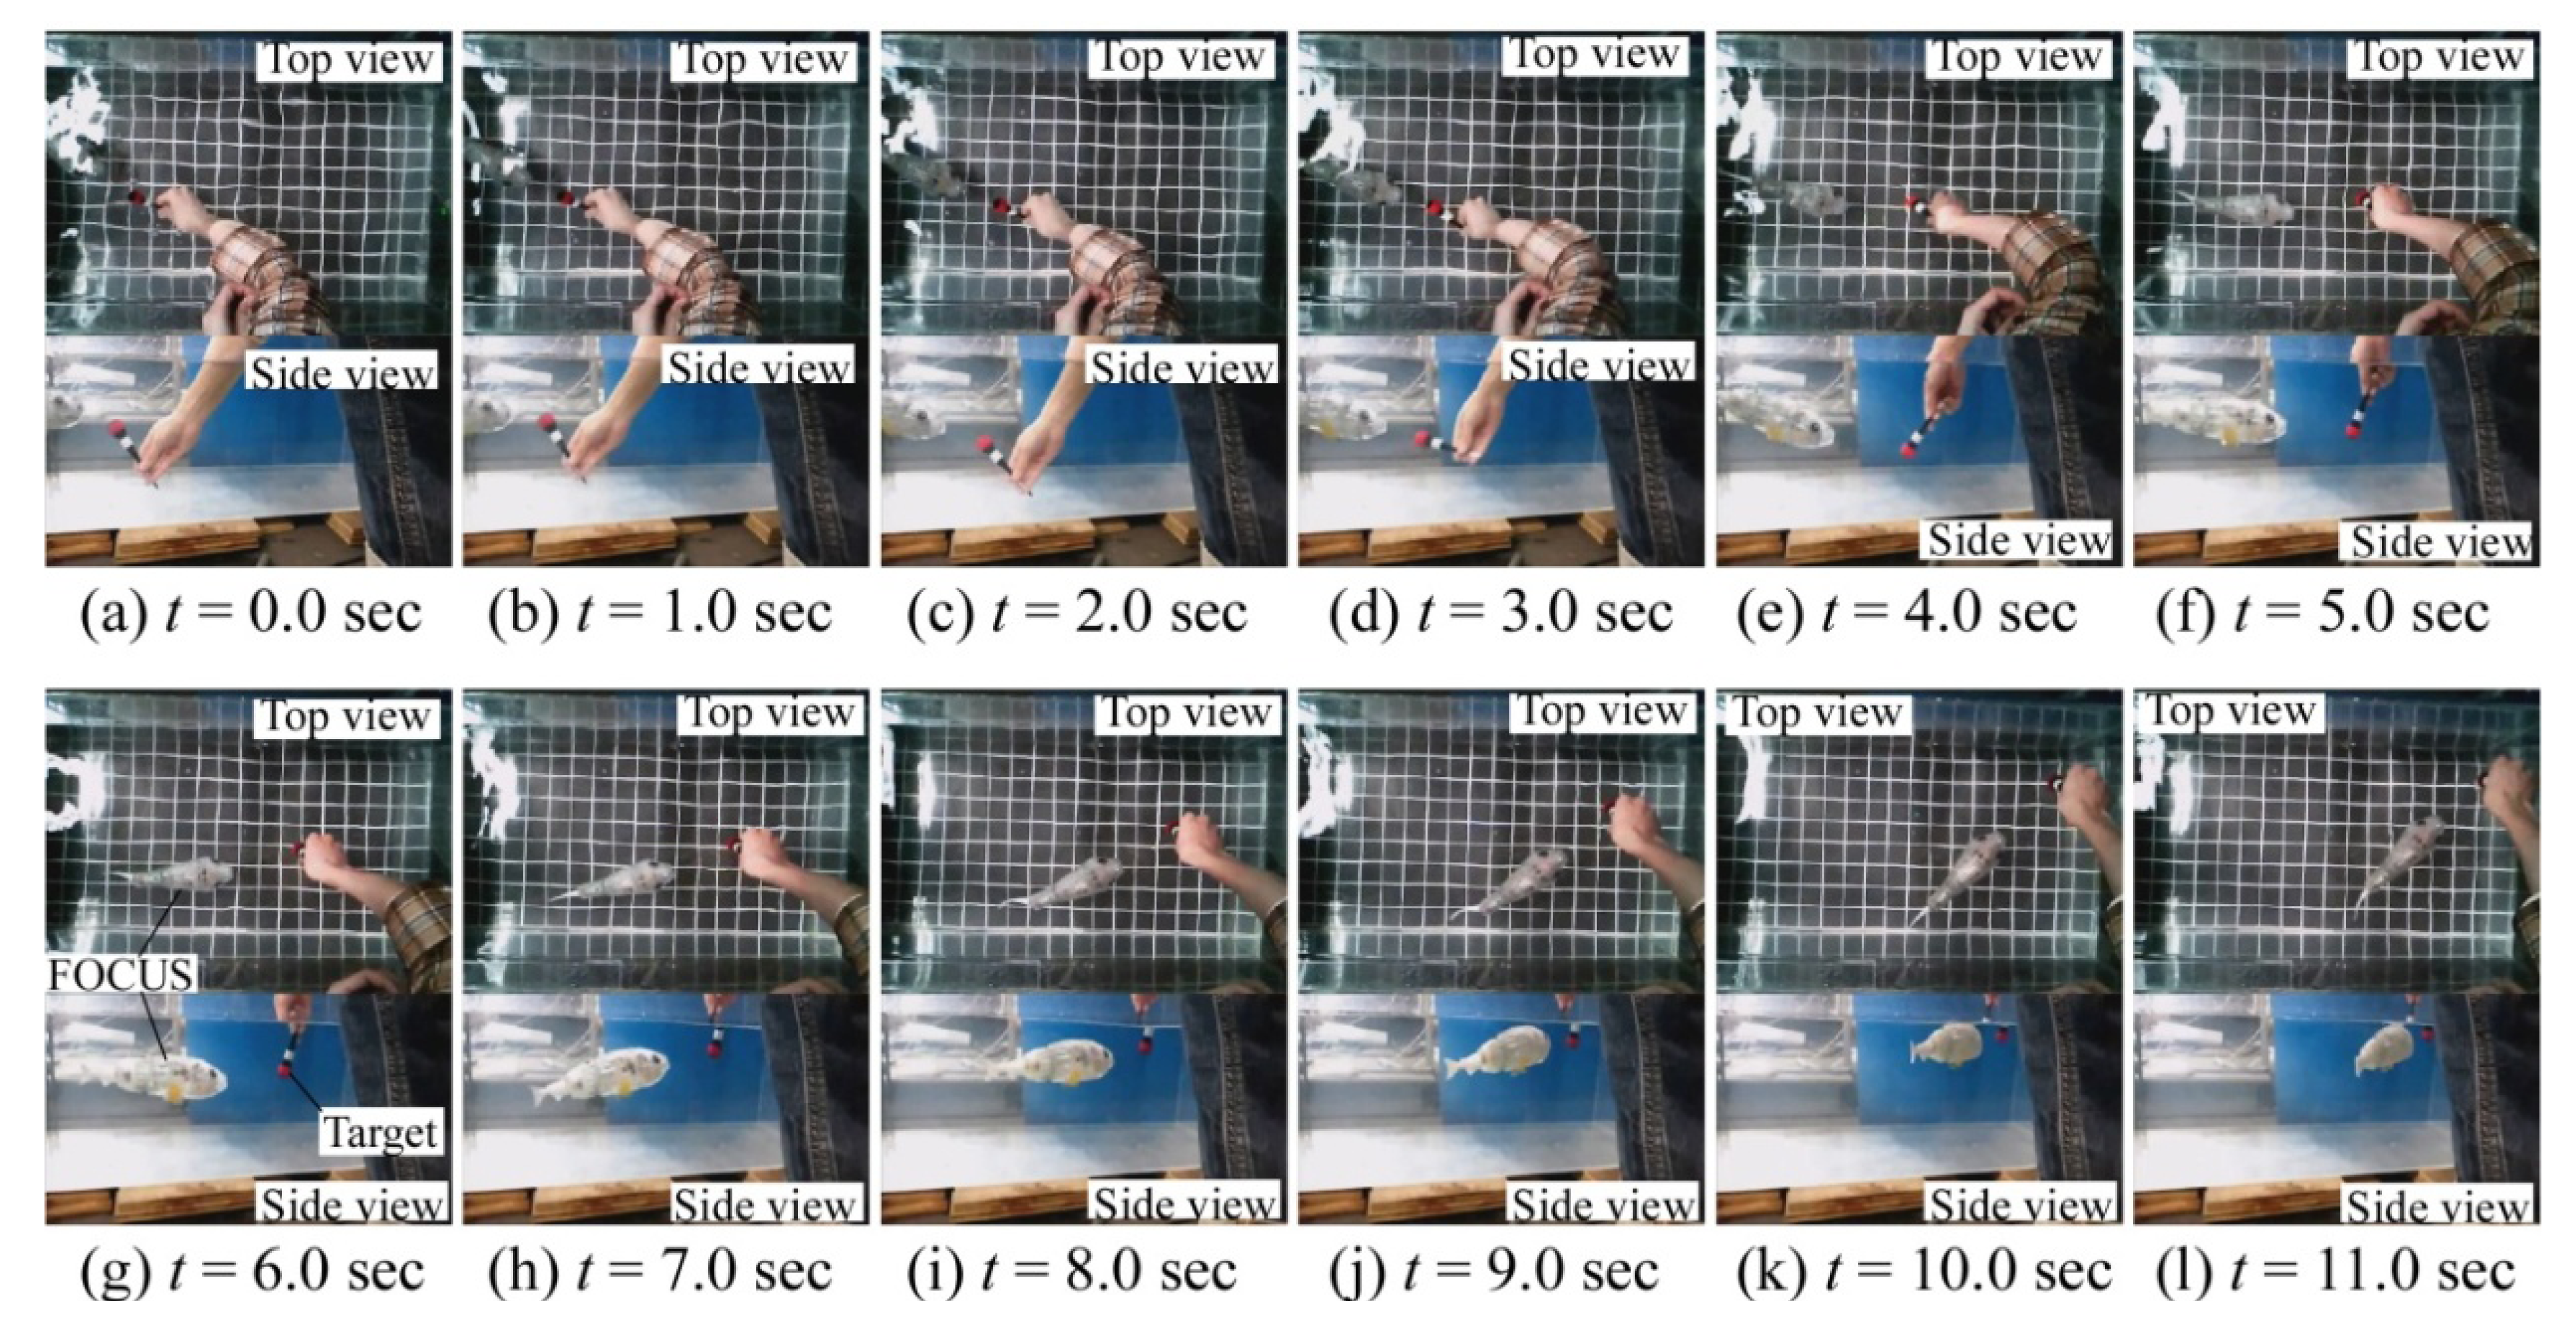
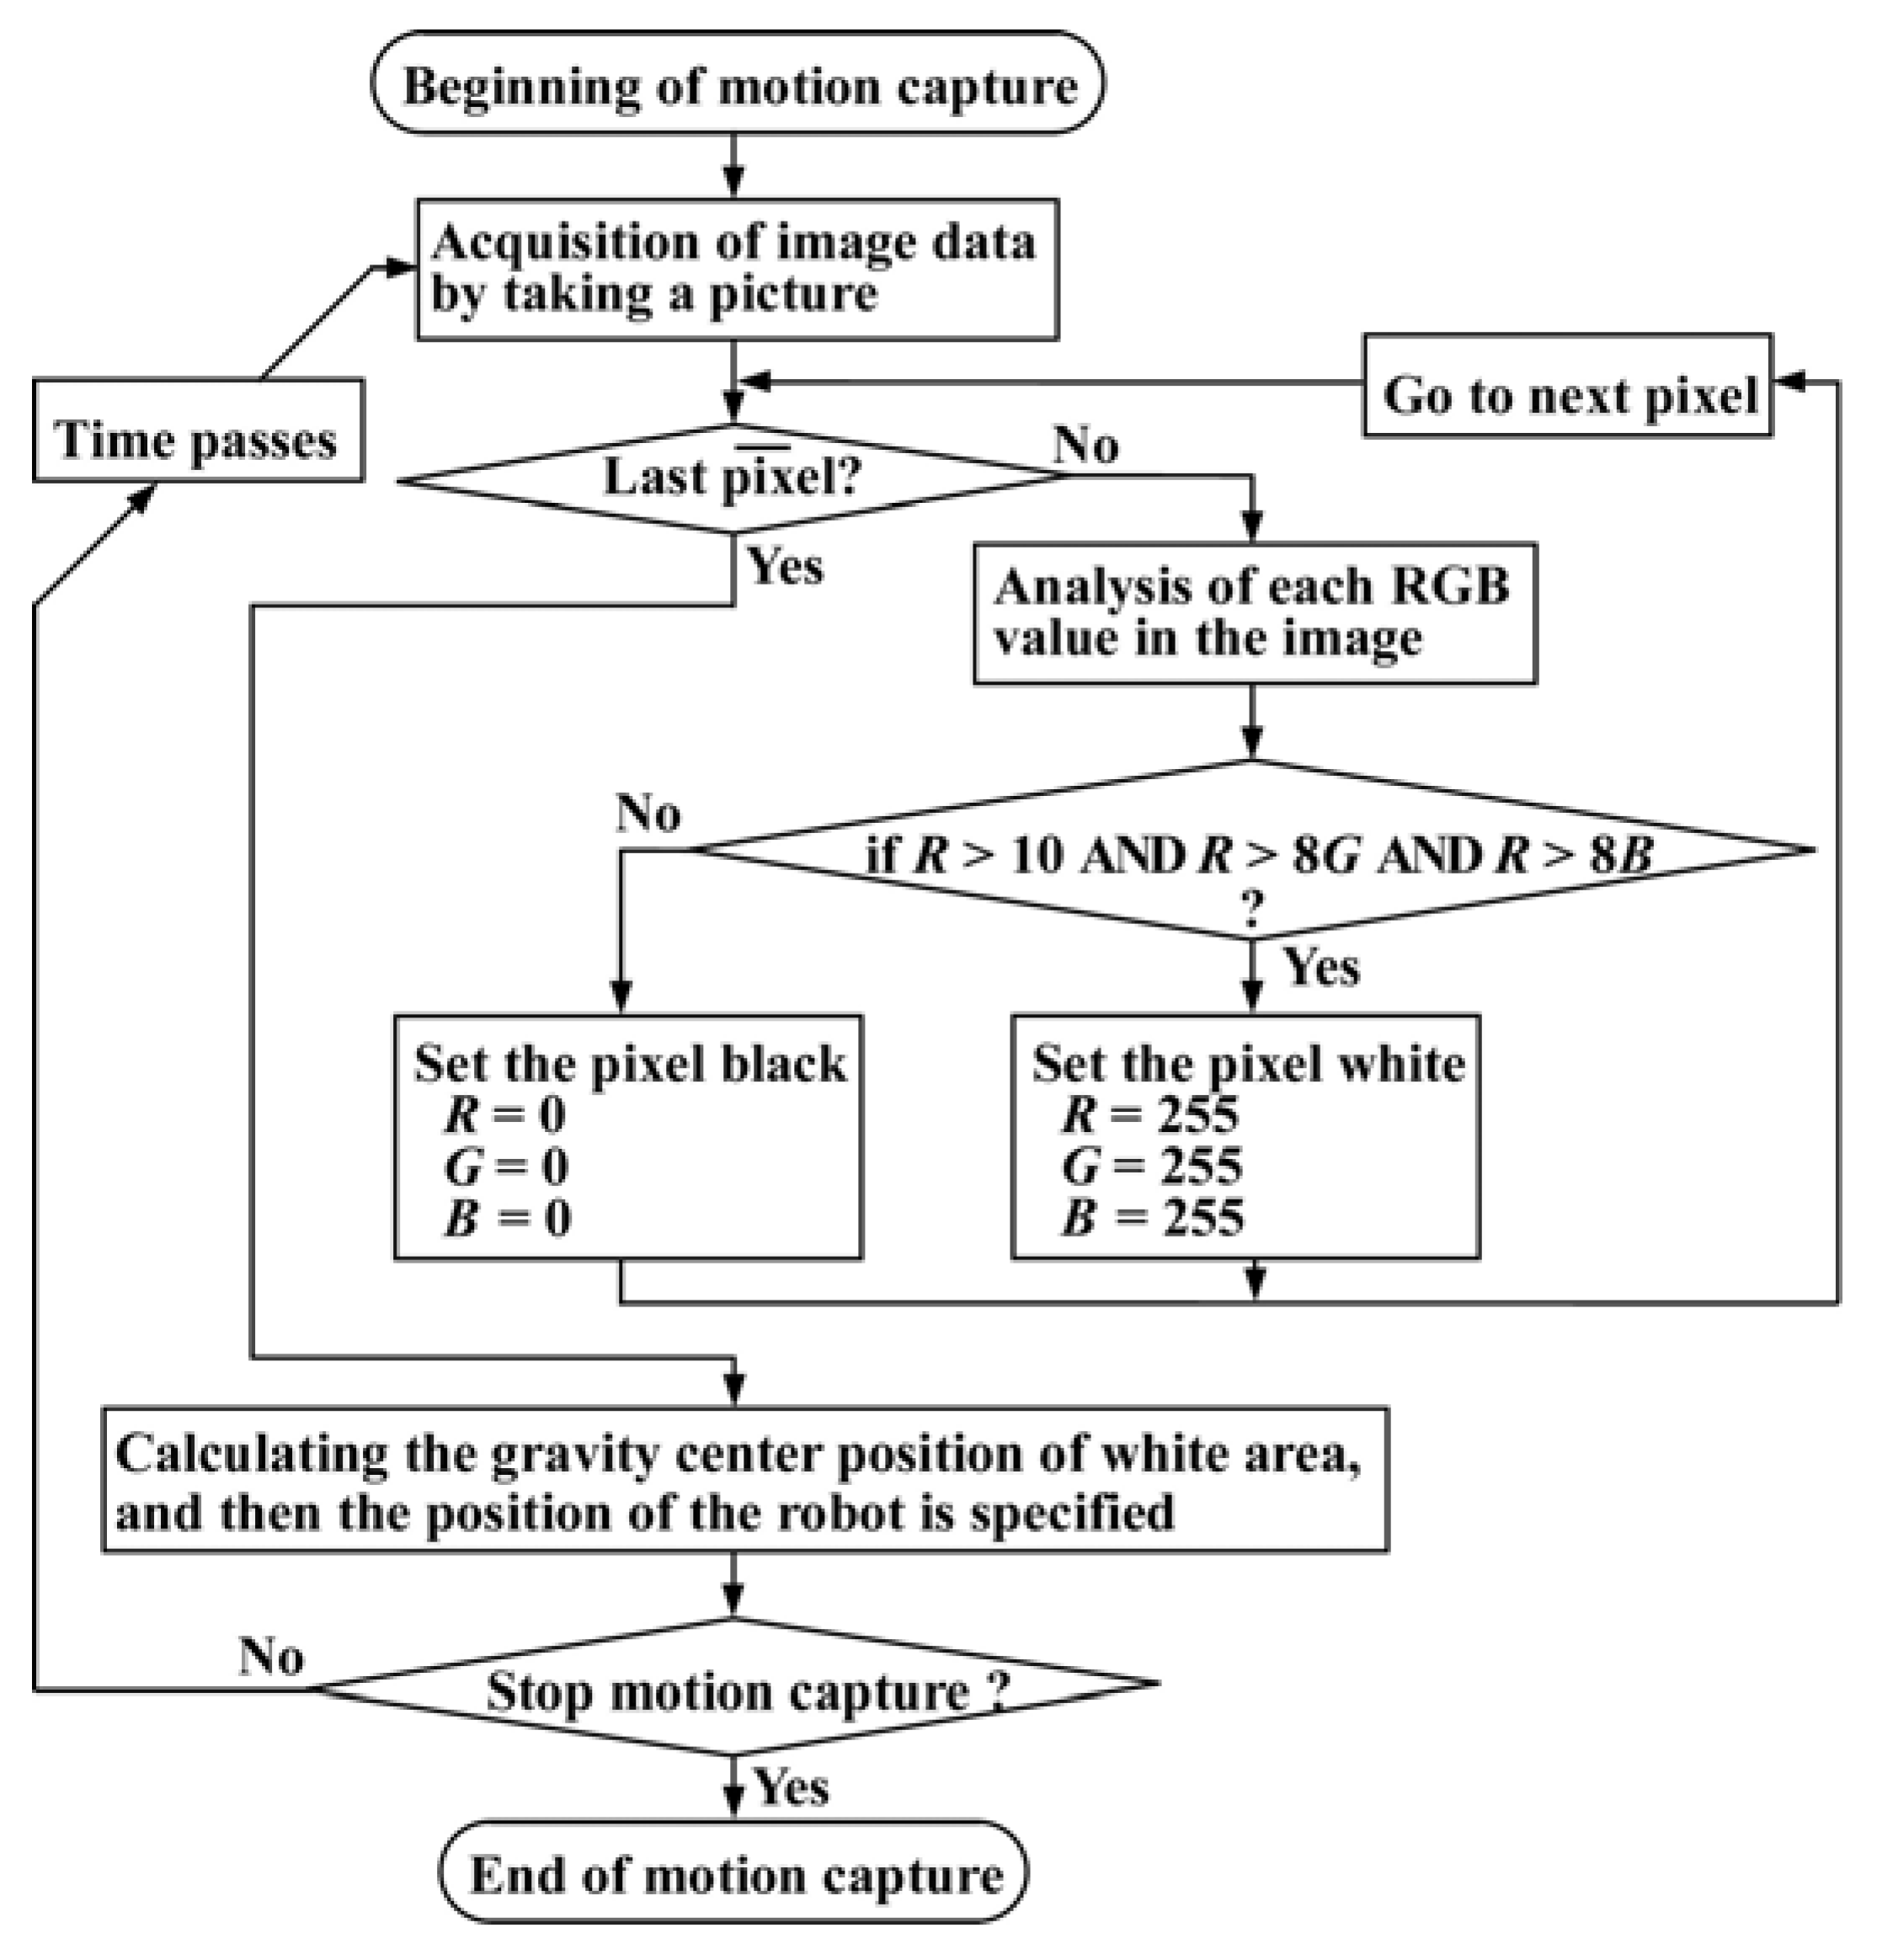
2.2. Target Tracking Method
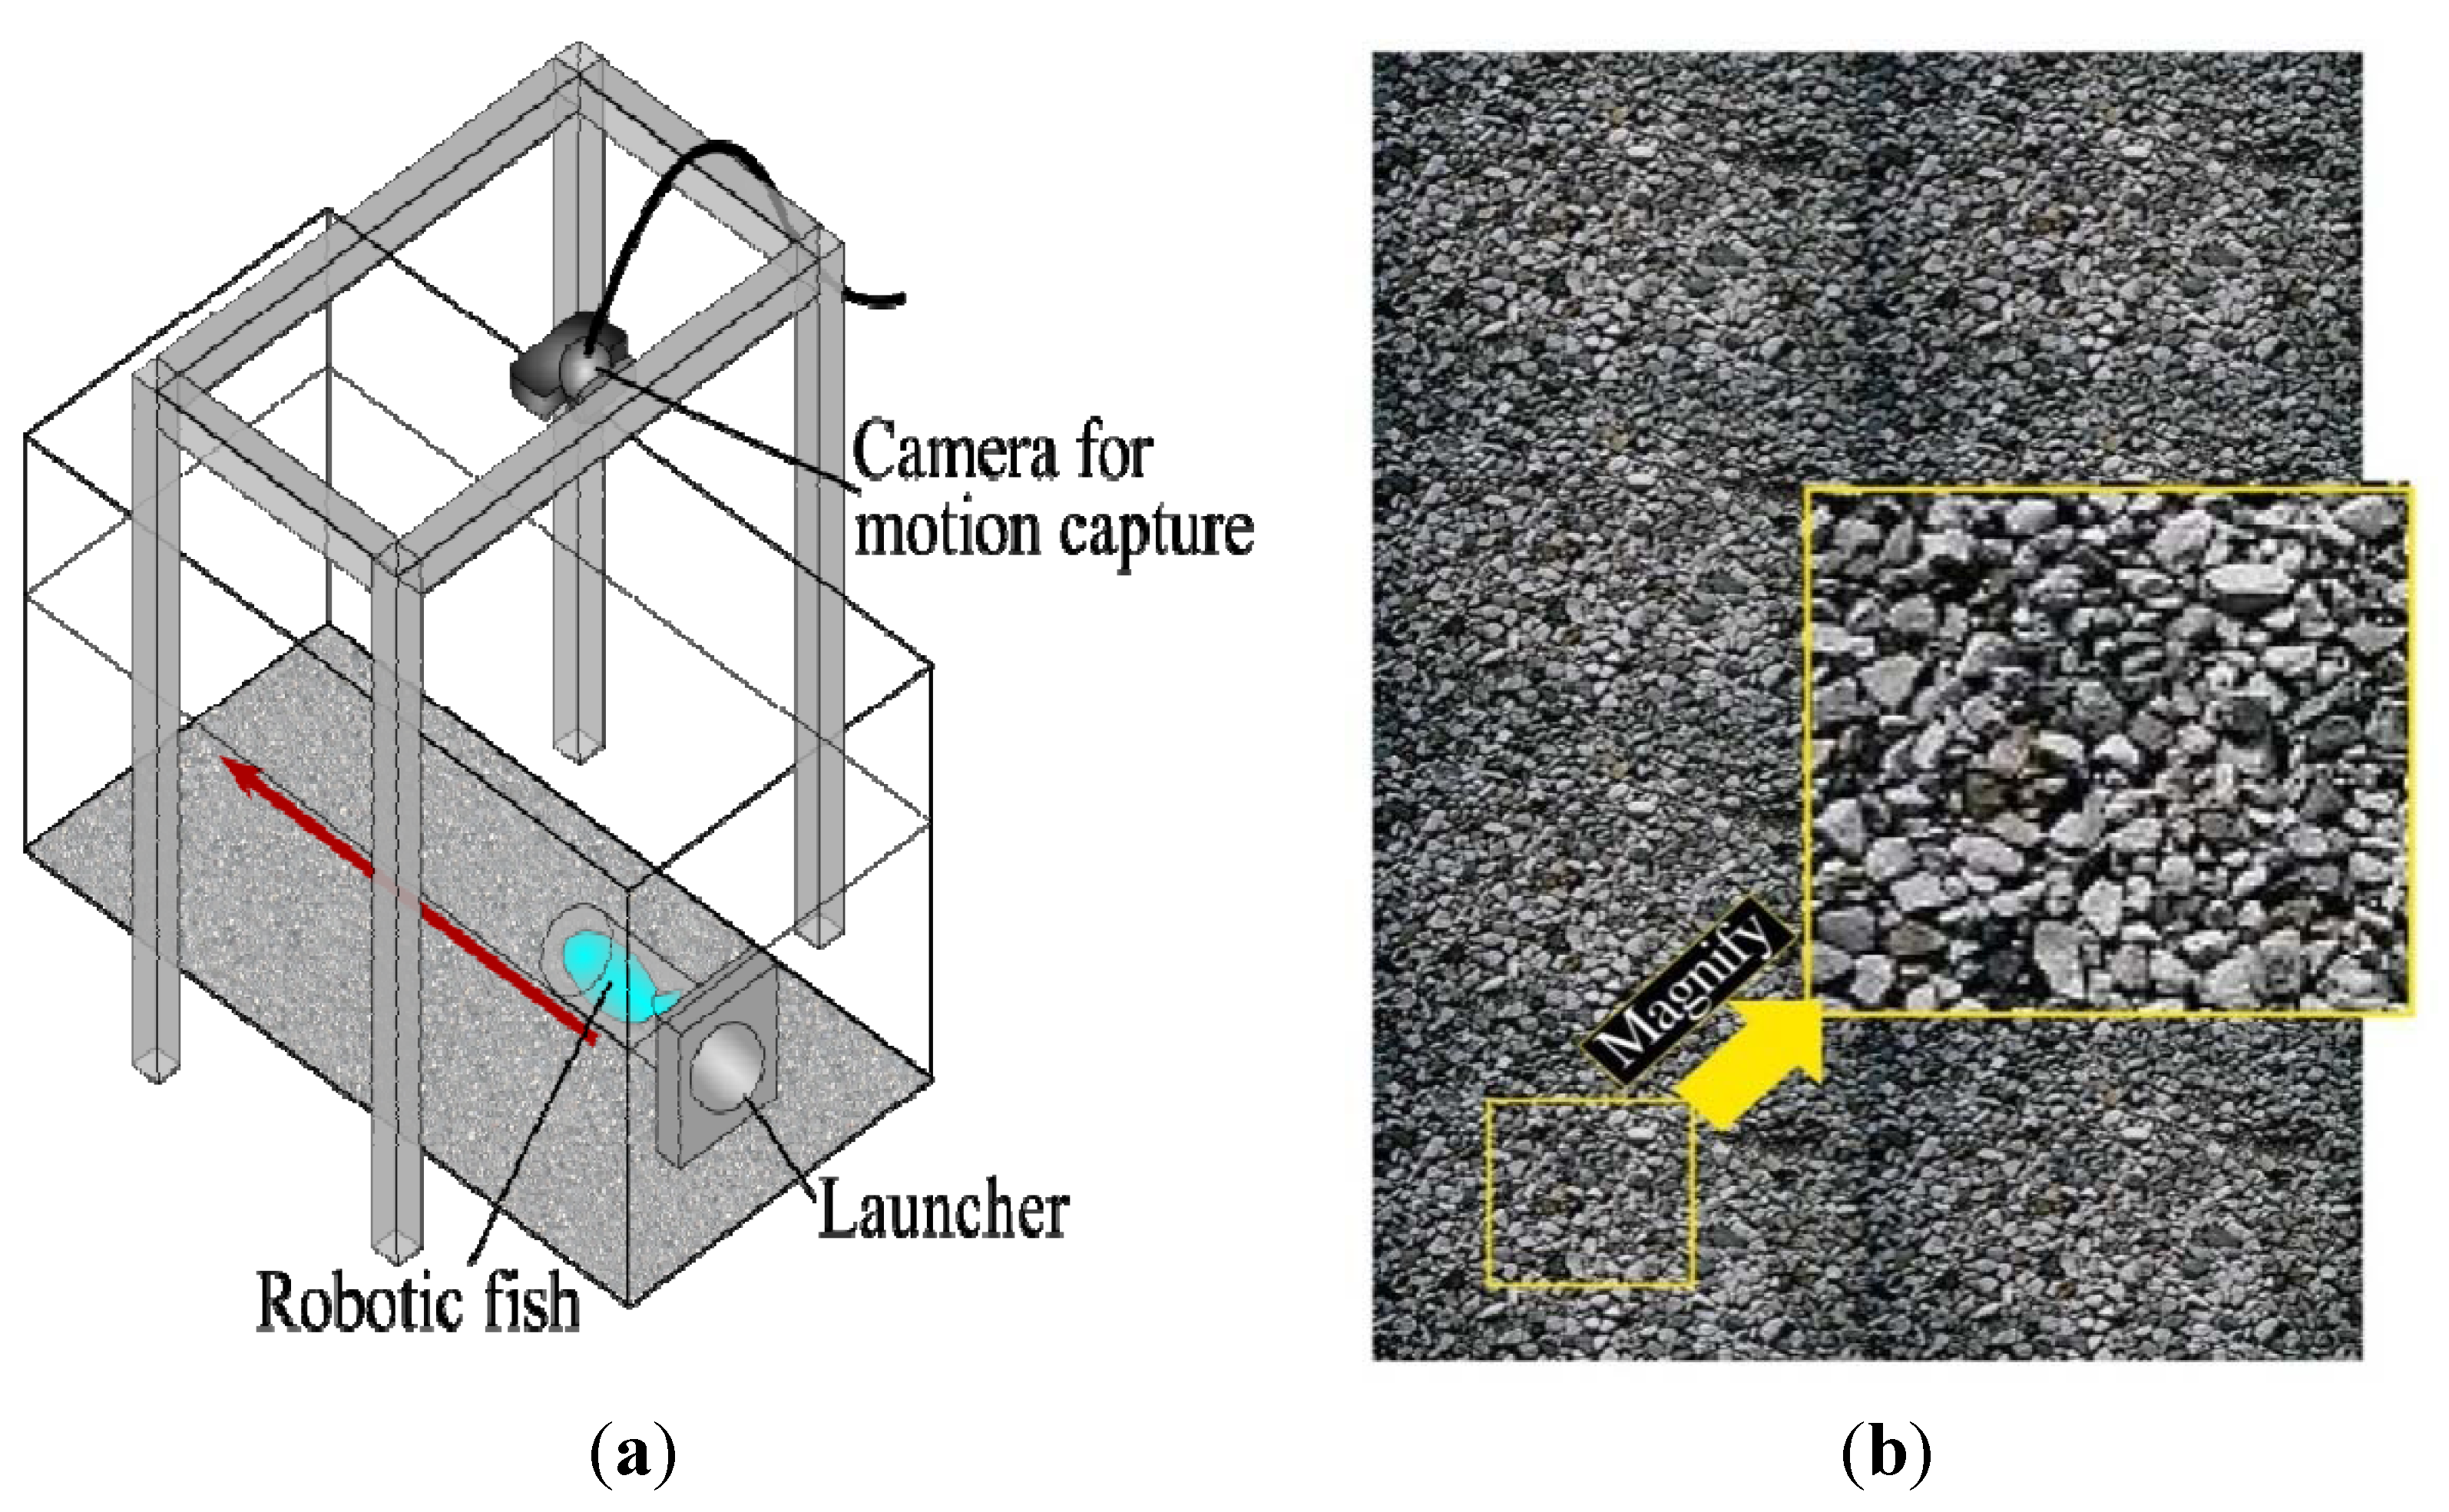
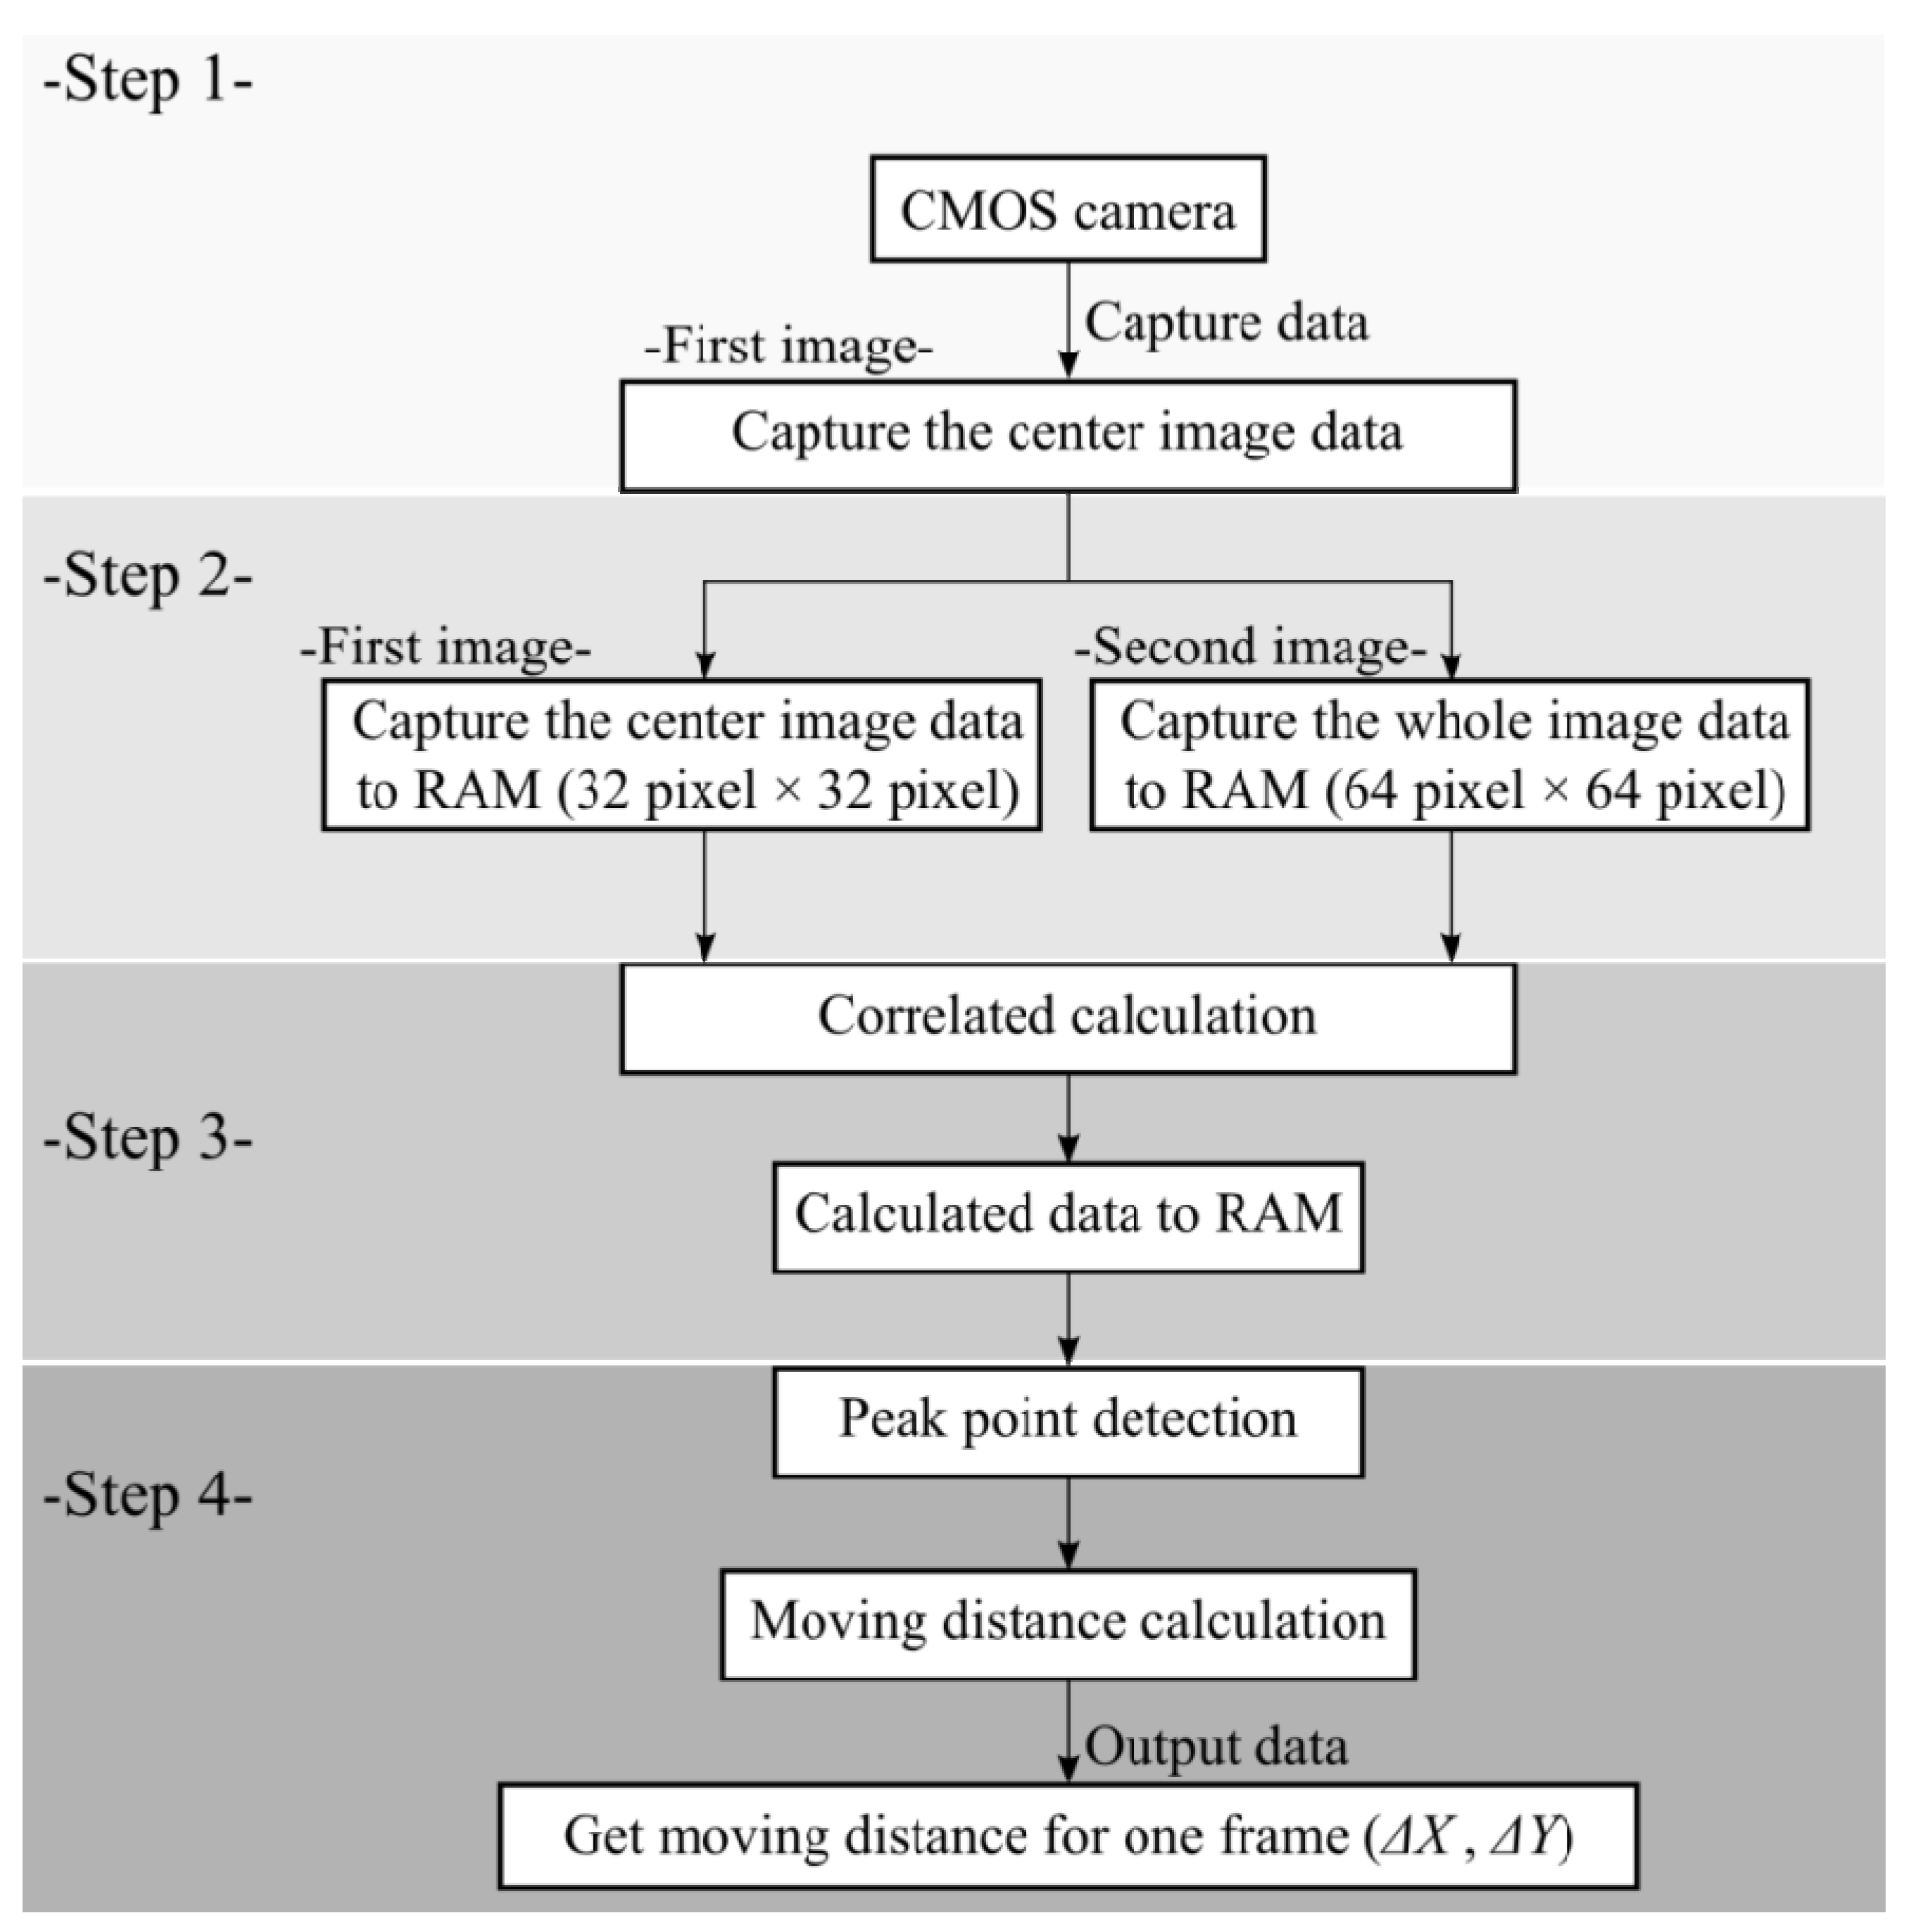
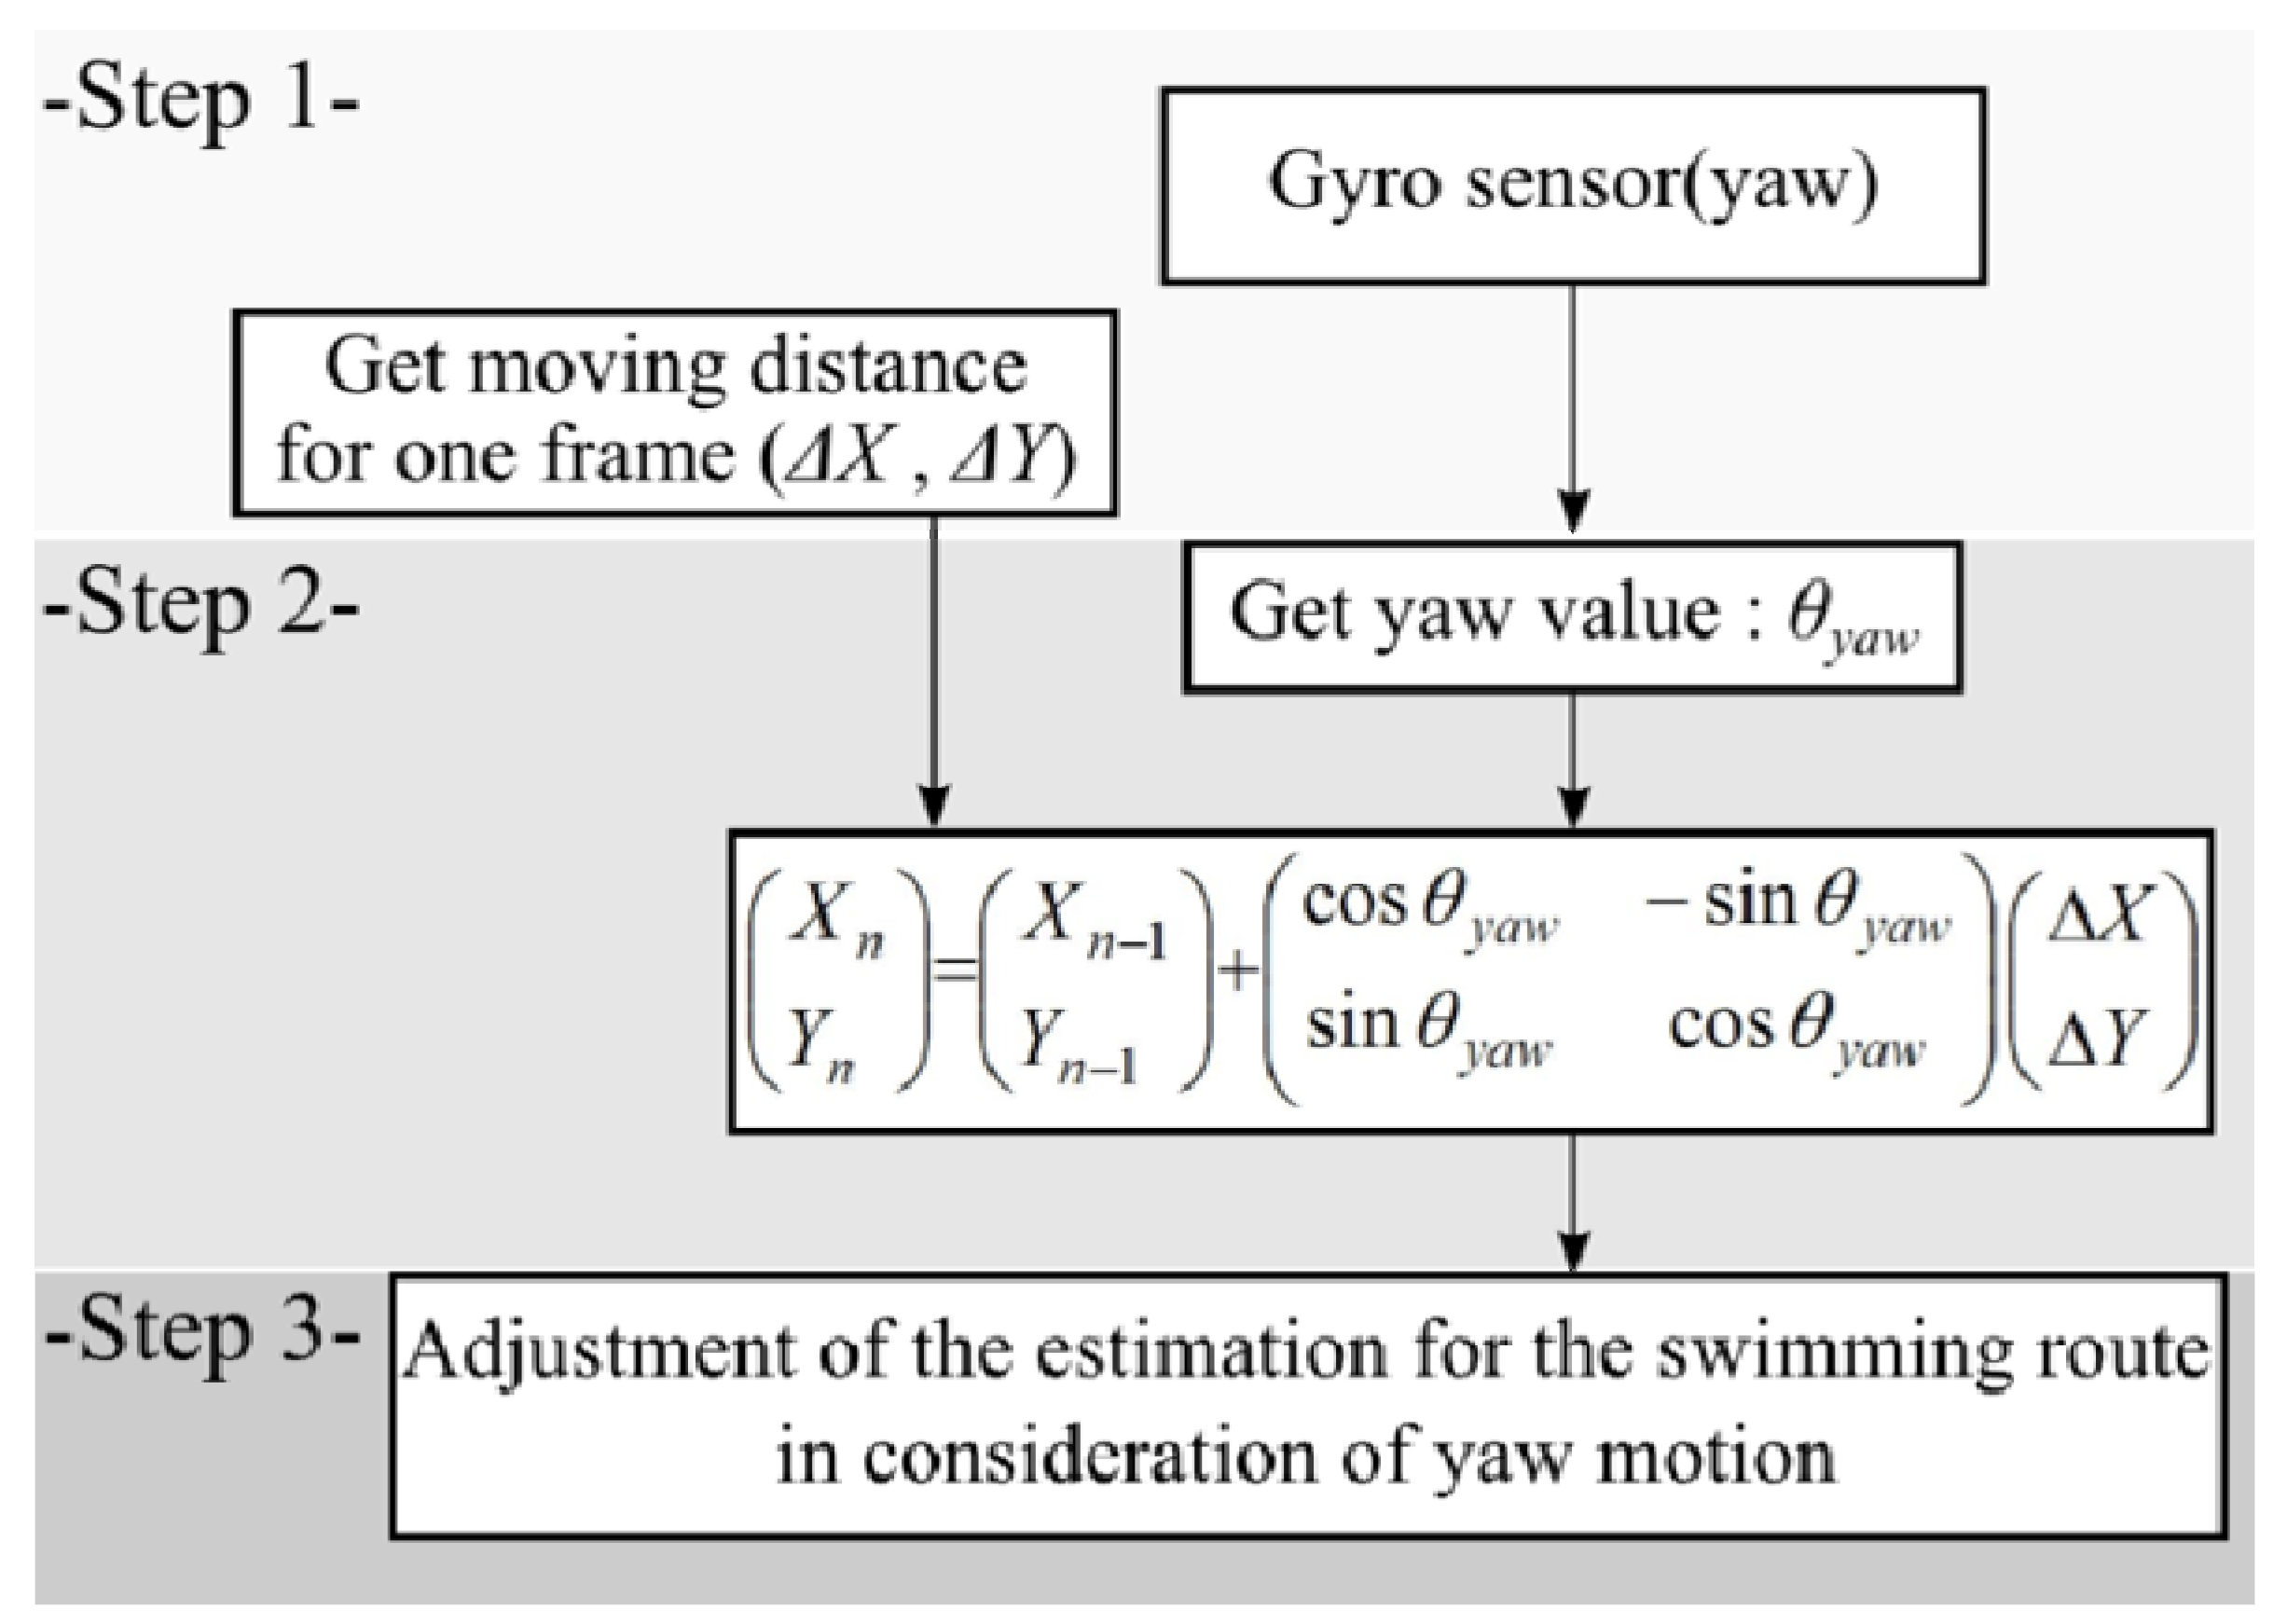
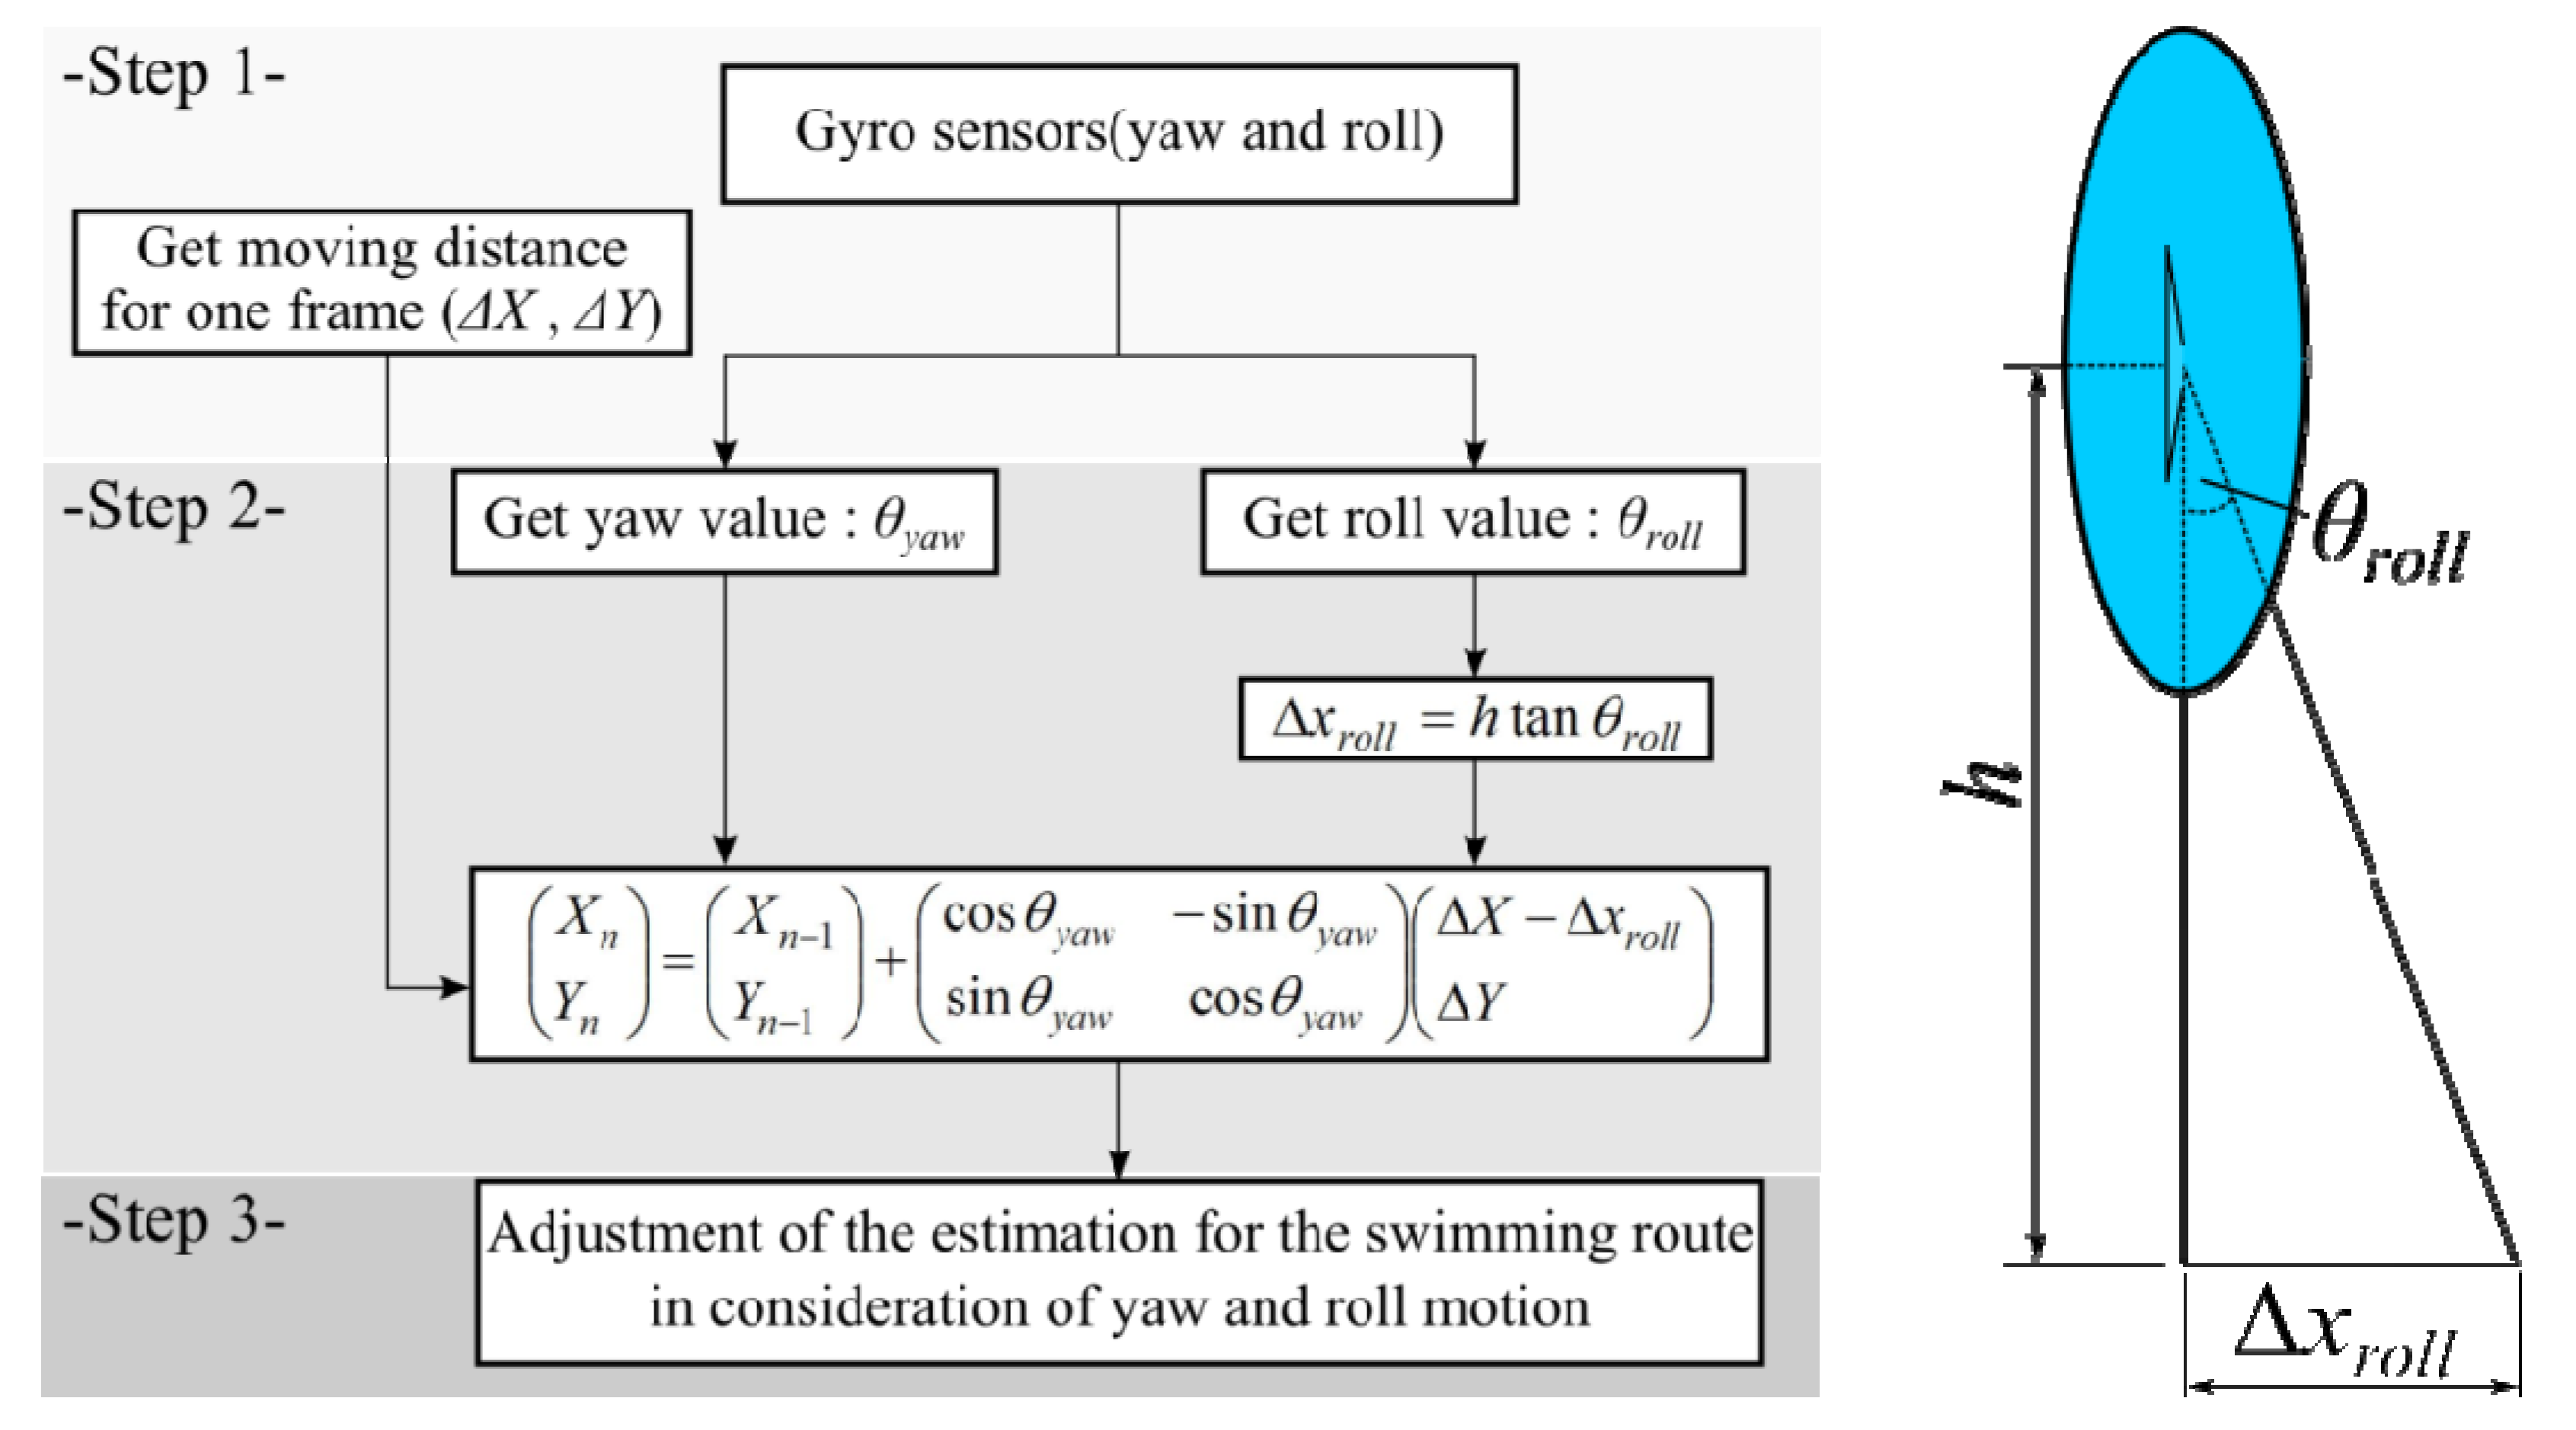
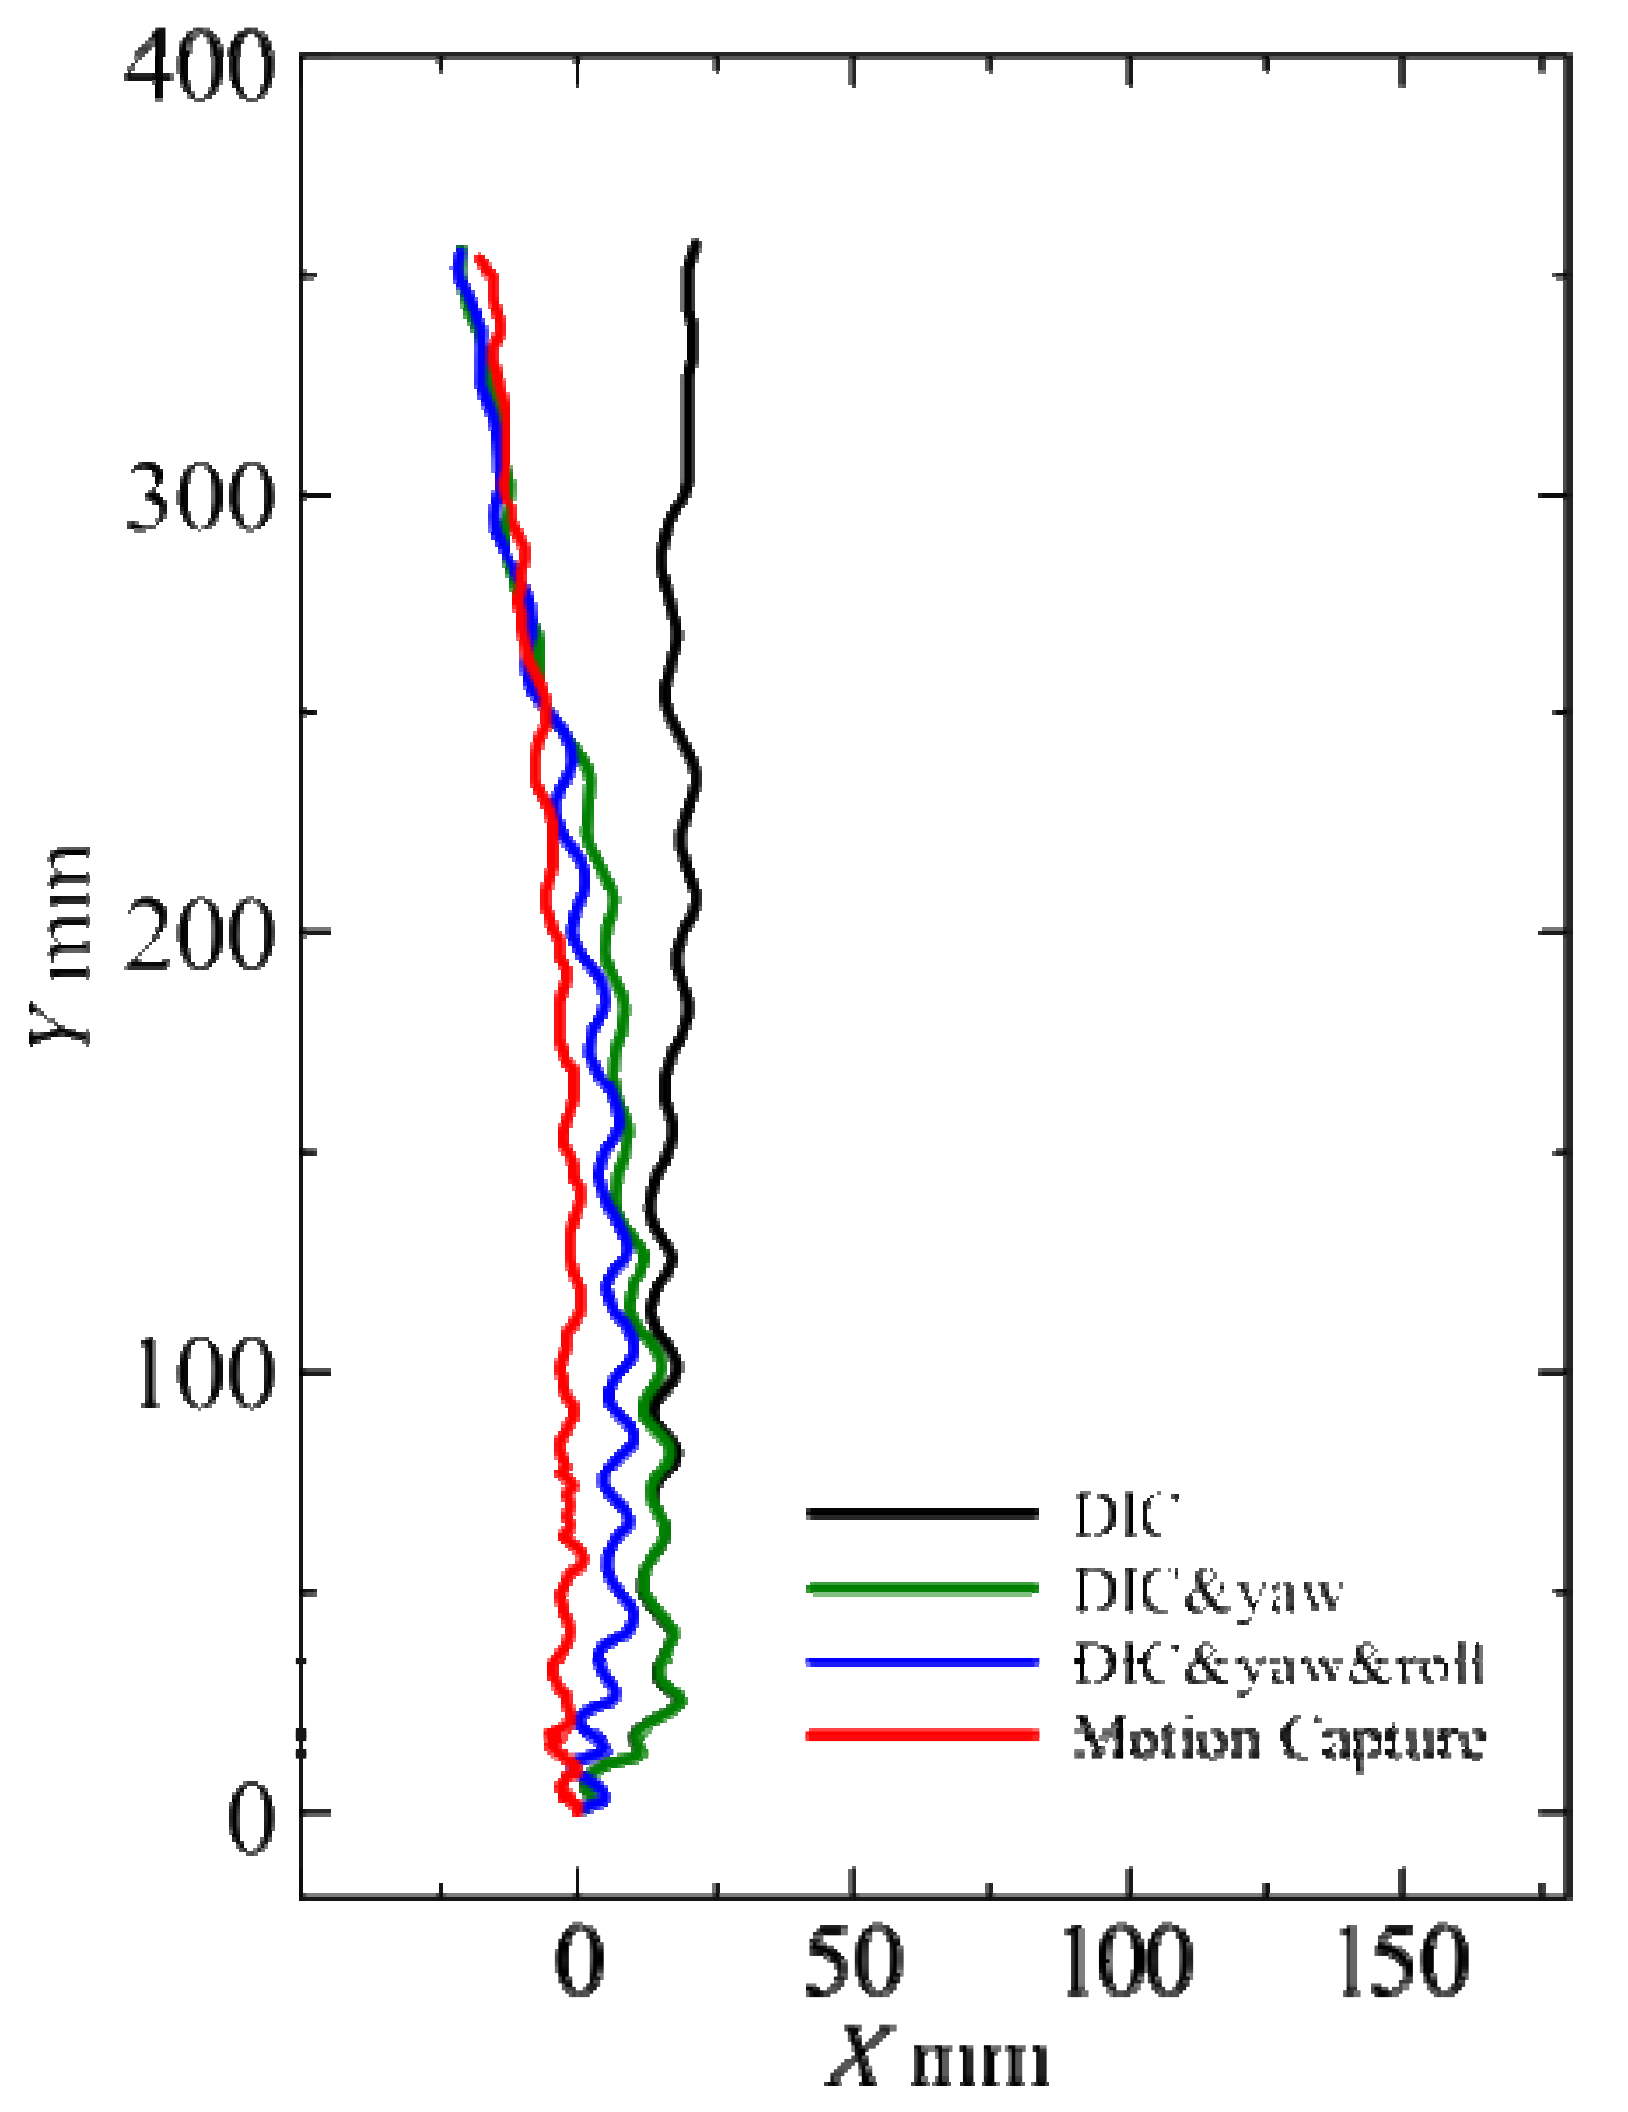
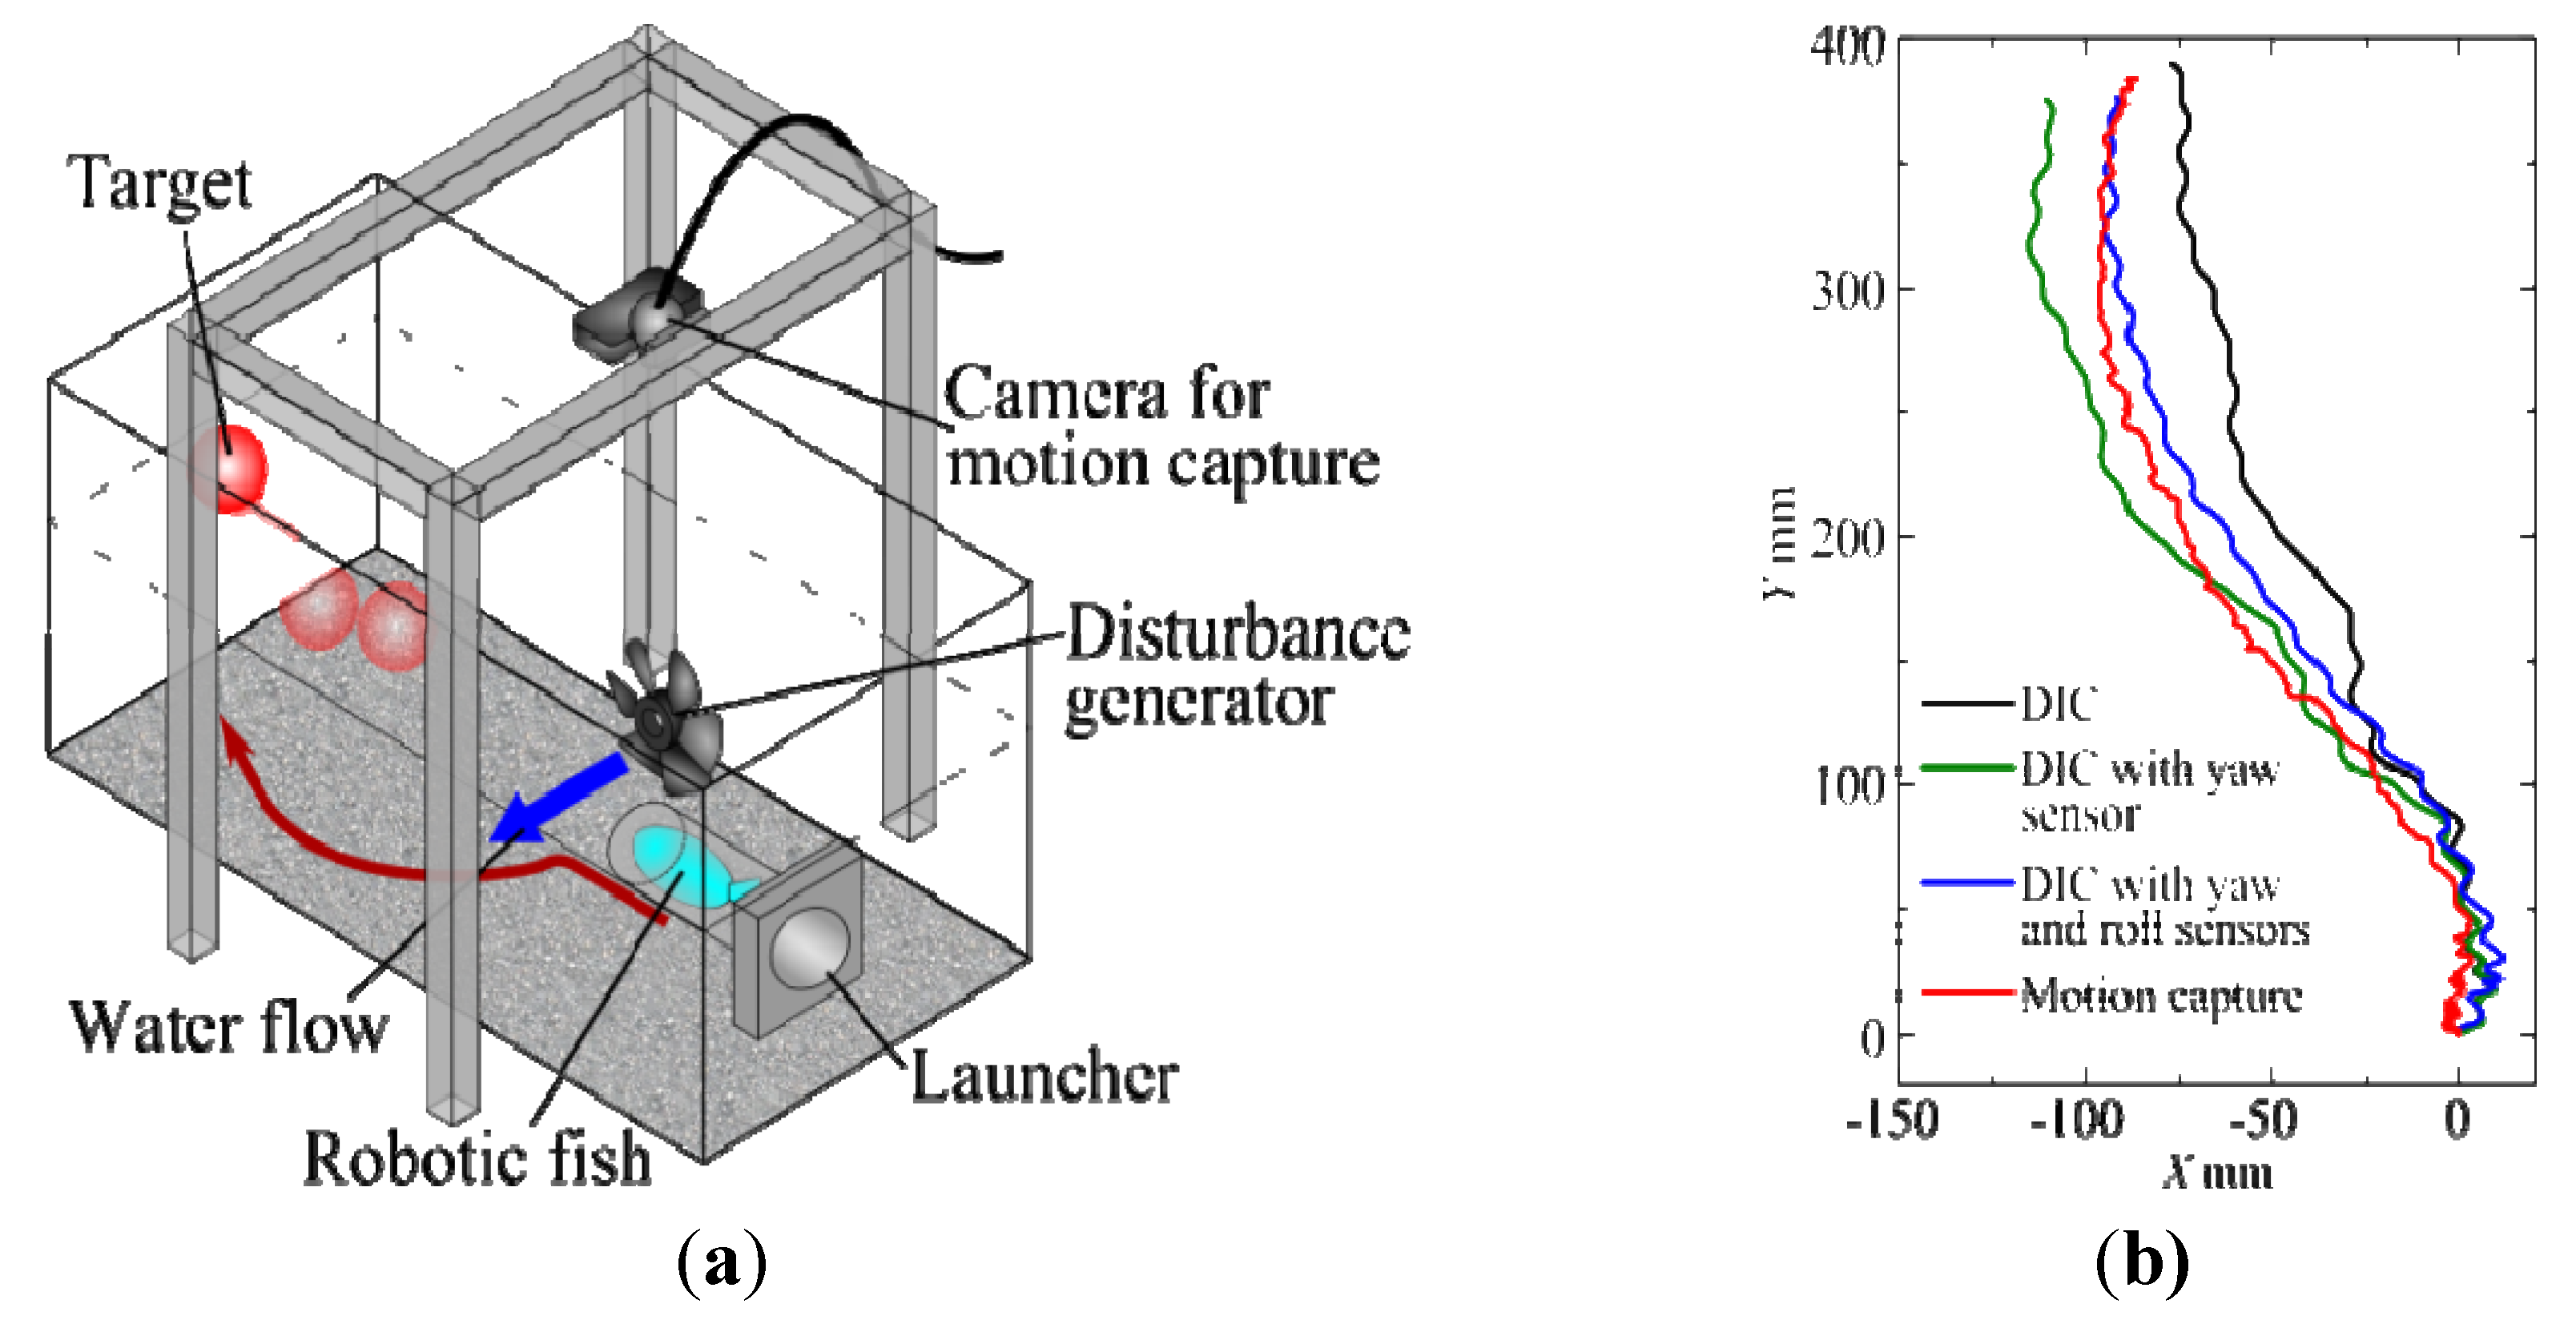
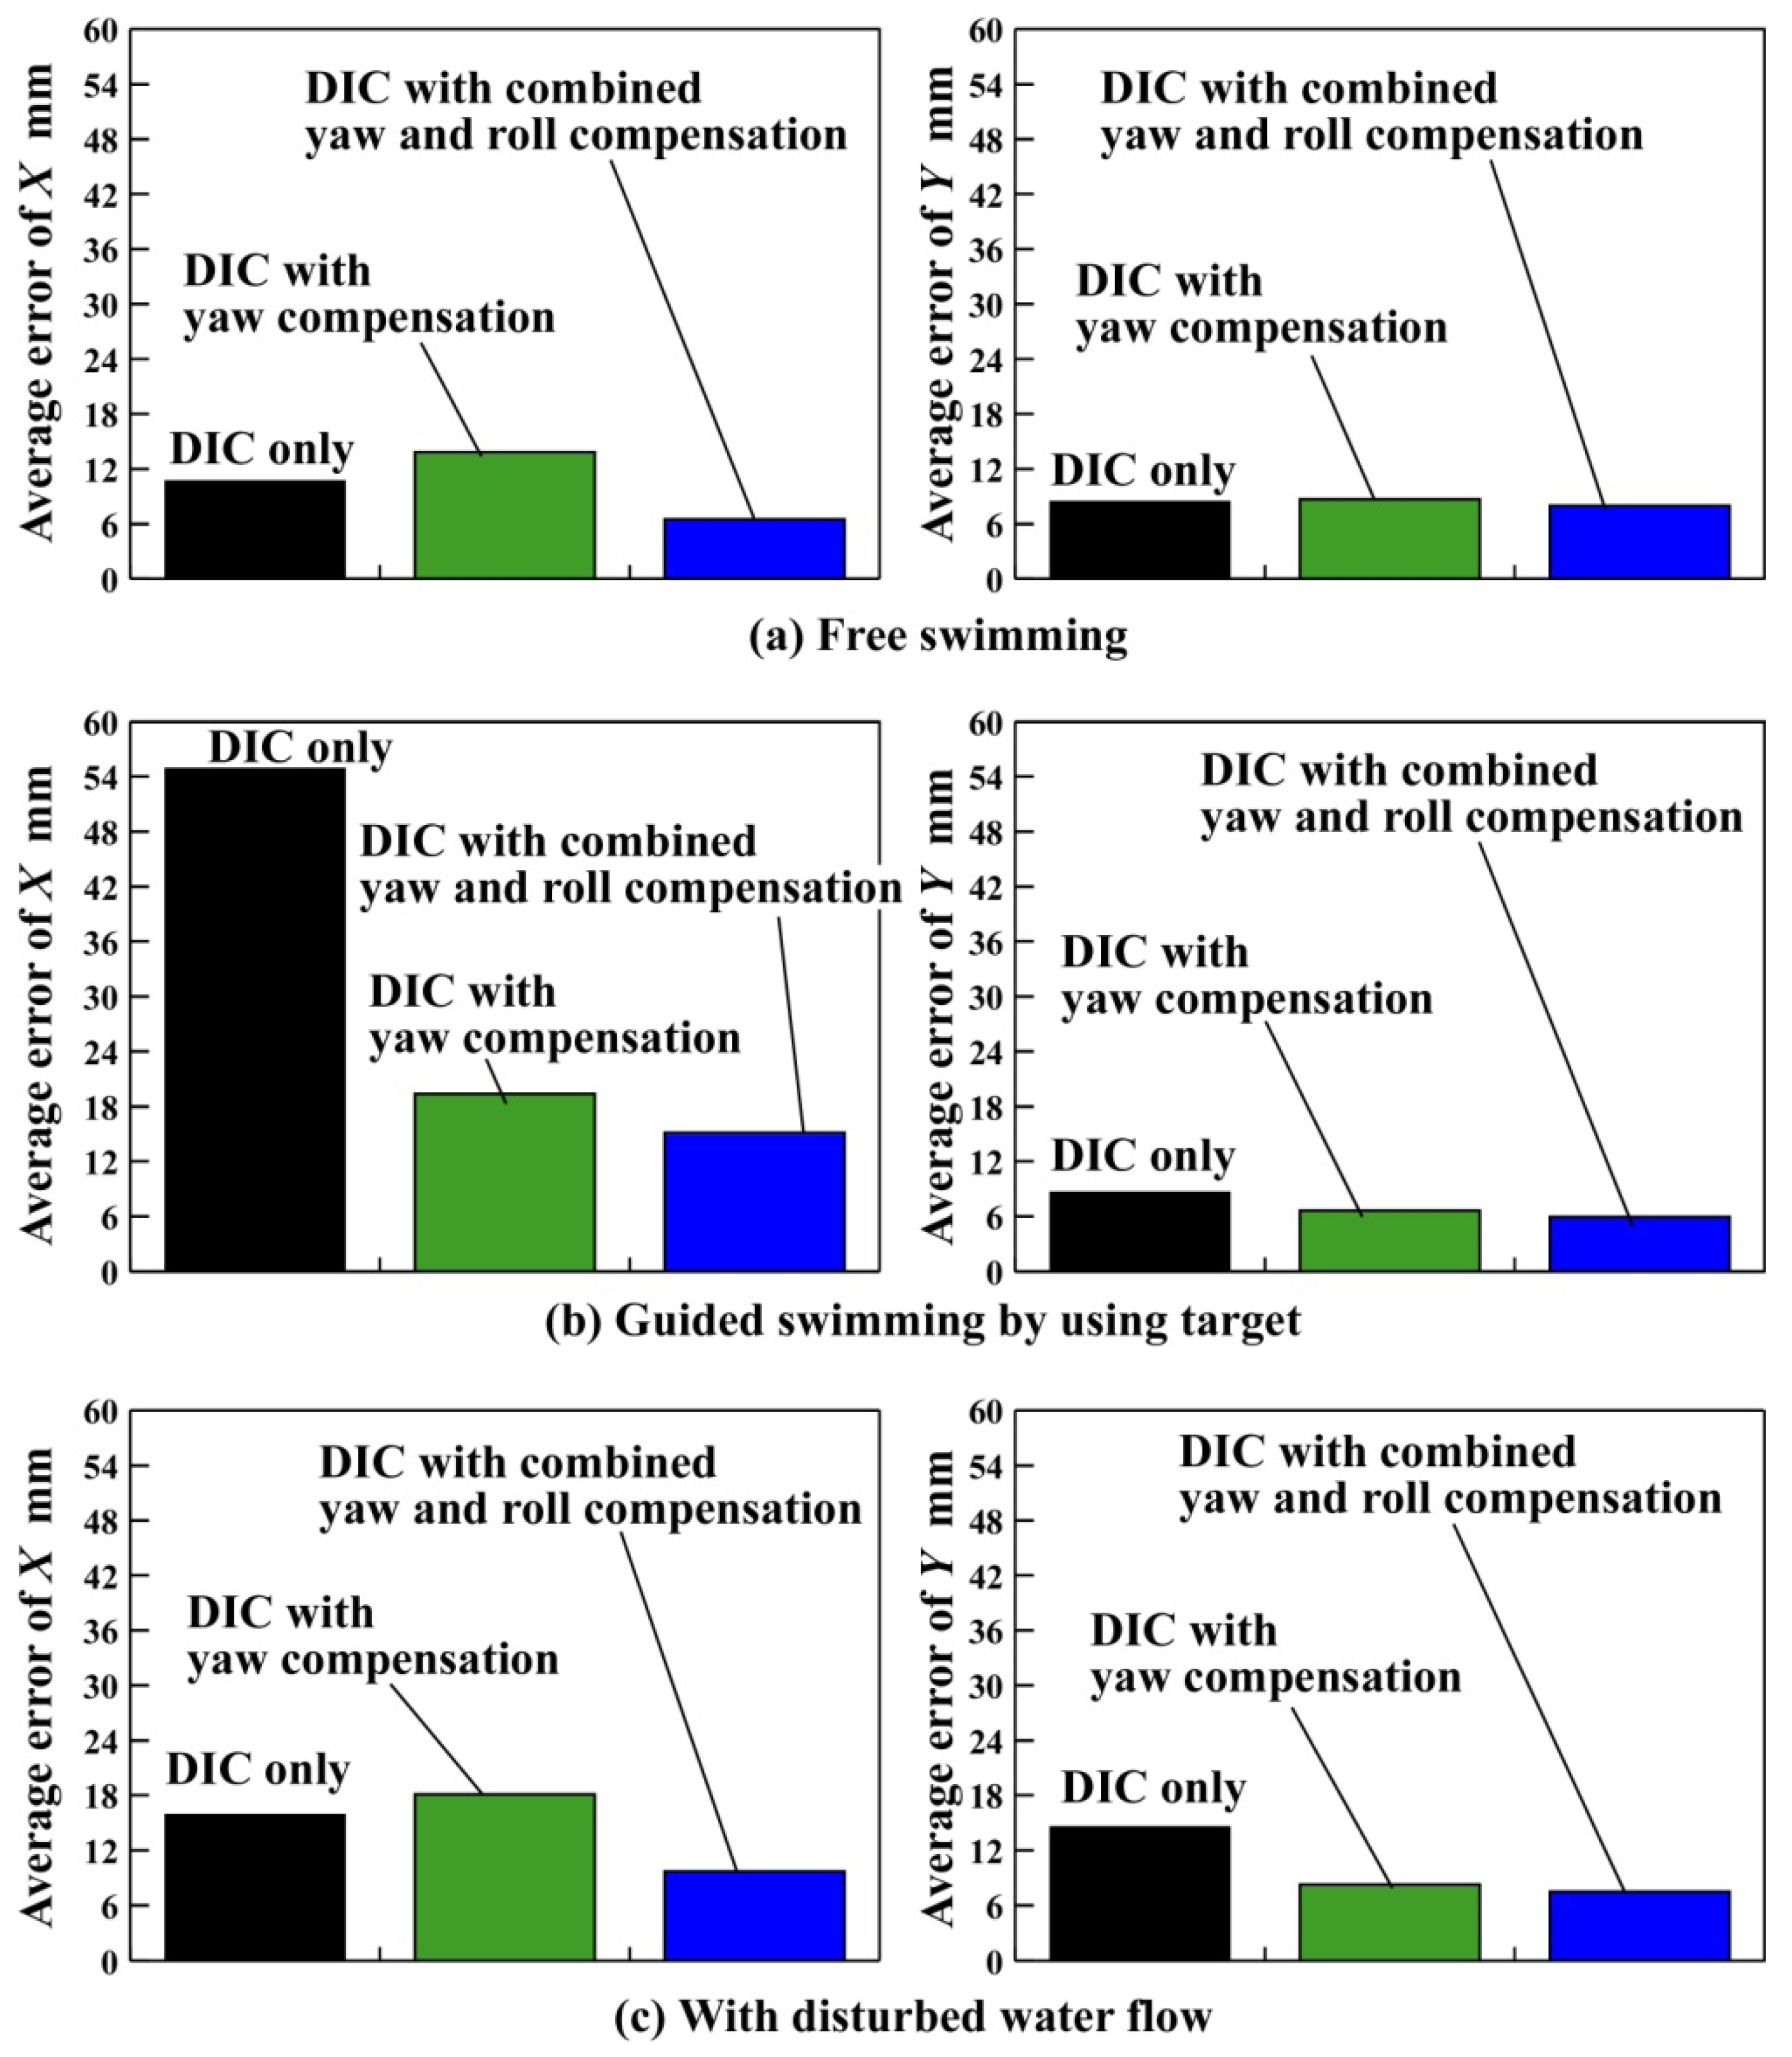
3. Position Estimation
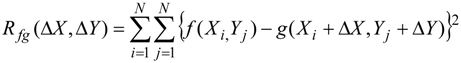

4. Conclusions
Acknowledgments
Author Contributions
Conflicts of Interest
References
- Hirata, K.; Takimoto, T.; Tamura, K. Study on turning performance of a fish robot. In Proceedings of the 1st International Symposium on Aqua Bio-Mechanisms, Honolulu, HI, USA, 28–30 August 2000; pp. 287–292.
- Nakashima, M.; Kaminaga, K.; Ono, K. Experimental study of two-joint dolphin robot (propulsive characteristics of 2nd large model). In Proceedings of the International Symposium on Aqua Bio-Mechanisms, Honolulu, HI, USA, 28–30 August 2000; pp. 311–314.
- Toda, Y.; Ikeda, H.; Sogihara, N. The motion of fish-like under-water vehicle two undulating side fins. In Proceedings of the 3rd International Symposium on Aqua Bio-Mechanisms, Okinawa, Japan, 3–7 July 2006.
- Kobayashi, S.; Nakabayashi, M.; Morikawa, H. Bioinspired propulsion mechanism in fluid using fin with dynamic variable-effective-length spring. J. Biomech. Sci. Eng. 2006, 1, 280–289. [Google Scholar] [CrossRef]
- Yamamoto, I. Research and development of robotic fish. J. JIME 2008, 43, 99–102. [Google Scholar] [CrossRef]
- Low, K.H. Modelling and parametric study of modular undulating fin rays for fish robots. Mech. Mach. Theory 2009, 44, 615–632. [Google Scholar] [CrossRef]
- Takada, Y.; Araki, R.; Nonogaki, M.; Ebita, K.; Ishii, T.; Wakisaka, T. Development of small and ultra-light passive-type polymer electrolyte fuel cell and application to small fish robots. Trans. Jpn. Soc. Mech. Eng. Ser. B 2010, 76, 650–659. [Google Scholar]
- Takada, Y.; Araki, R.; Nakanishi, Y.; Nonogaki, M.; Ebita, K.; Wakisaka, T. Development of small fish robots powered by small and ultra-light passive-type polymer electrolyte fuel cells. J. Robot. Mechatron. 2010, 22, 150–157. [Google Scholar]
- Takada, Y.; Masuda, H.; Tajiri, T.; Wakisaka, T. Development of small fish robot with built-in fuel cells. In Proceedings of the Techno-Ocean, Kobe, Japan, 27 July 2010.
- Techno-Ocean 2010 Pre Event, Ocean Science Seminar, Amazing World of Aqua Bio Mechanics. Available online: http://www.marine.osakafu-u.ac.jp/~lab06/pre-event/ (accessed on 28 January 2014).
- Asakawa, K.; Kojima, J.; Ito, Y.; Takagi, S.; Shirasaki, Y.; Kato, N. Autonomous underwater vehicle AQUA EXPLORER 1000 for inspection of underwater cables. In Proceedings of the AUV’96, Monterey, CA, USA, 2–6 June 1996.
- Ura, T. Construction of AUV R2D4 based on the success of full-autonomous exploration of Teisi Knoll by R-one robot. In Proceedings of the AUV Show Case, New Maiden, UK, 27–28 September 2002; pp. 23–28.
- Maeda, T.; Ishiguro, S.; Yokoyama, K.; Hirokawa, K.; Hashimoto, A.; Okuda, Y.; Tani, T. development of fuel cell AUV “URASHIMA”. Mitsubishi Heavy Ind. Tech. Rev. 2004, 41, 344–347. [Google Scholar]
- Nakatani, T.; Ura, T.; Ito, Y.; Kojima, J.; Tamura, K.; Sakamaki, T.; Nose, Y. AUV “TUNA-SAND” and its Exploration of hydrothermal vents at Kagoshima Bay. In Porceedings of the OCEANS 2008—MTS/IEEE Kobe Techno-Ocean, Kobe, Japan, 8–11 April 2008.
- Hyakudome, T.; Furuyama, H.; Baba, T.; Kasaya, T.; Oomika, S.; Ishibashi, S.; Yoshida, H.; Tsukioka, S.; Matsuura, M.; Aoki, T. The Seafloors Which AUV “URASHIMA” Watched. Available online: http://jairo.nii.ac.jp/0153/00013762/en (accessed on 15 March 2014).
- Sakagami, N.; Ibata, D.; Ikeda, T.; Shibata, M.; Ueda, T.; Ishimaru, K.; Onishi, H.; Murakami, S.; Kawamura, S. Development of a removable multi-DOF manipulator system for man-portable underwater robots. In Proceedings of the 21th International Offshore and Polar Engineering Conference, Maui, HI, USA, 19–24 June 2011; pp. 279–284.
- Takada, Y.; Nakanishi, Y.; Araki, R.; Wakisaka, T. Investigation of propulsive force and water flow around a small fish robot by PIV Measurement and three-dimensional numerical analysis. Trans. Jpn. Soc. Mech. Eng. Ser. C 2010, 76, 665–672. [Google Scholar]
- Takada, Y.; Nakanishi, Y.; Araki, R.; Nonogaki, M.; Wakisaka, T. Effect of material and thickness about tail fins on propulsive performance of a small fish robot. J. Aero Aqua Bio-Mech. 2010, 1, 51–56. [Google Scholar] [CrossRef]
- Takada, Y.; Araki, R.; Ochiai, T.; Tajiri, T.; Wakisaka, T. Effects of tail fin flexibility on propulsive performance in small fish robots (investigation by fluid-structure interaction analysis considering elastic deformation of tail fin). Trans. Jpn. Soc. Mech. Eng. Ser. C 2011, 77, 2351–2362. [Google Scholar] [CrossRef]
- Takada, Y.; Ochiai, T.; Fukuzaki, N.; Tajiri, T.; Wakisaka, T. Analysis of flow around robotic fish by three-dimensional fluid-structure interaction simulation and evaluation of propulsive performance. J. Aero Aqua Bio-Mech. 2013, 3, 57–64. [Google Scholar] [CrossRef]
- Takada, Y.; Fukuzaki, N.; Ochiai, T.; Tajiri, T.; Wakisaka, T. Evaluation of artificial caudal fin for fish robot with two joints by using three-dimensional fluid-structure simulation. Adv. Mech. Eng. 2013, 2013. ID:310432. [Google Scholar] [CrossRef]
- Takada, T.; Nakamura, T.; Koyama, K.; Tajiri, T. Target following control of small fish robot FOCUS based on color information. Trans. Jpn. Soc. Mech. Eng.Ser. C 2012, 78, 2924–2934. [Google Scholar] [CrossRef]
- Takada, Y.; Nakamura, T.; Koyama, K.; Wakisaka, T. Self-position estimation of small fish robot based on visual information from camera. J. Jpn. Inst. Mar. Eng. 2012, 47, 138–146. [Google Scholar]
- Takada, Y.; Nakamura, T.; Koyama, K.; Fukuzaki, N.; Tajiri, T.; Wakisaka, T. Target following and self-position estimation of small fish robot FOCUS. J. Jpn. Inst. Mar. Eng. 2012, 47, 108–113. [Google Scholar]
- Kawasue, K.; Ishimatsu, T.; Shih, C. Fast correlation technique of particle image velocimetry. Trans. Jpn. Soc. Mech. Eng. Ser. C 1994, 60, 2084–2089. [Google Scholar] [CrossRef]
- Uneda, M.; Murata, S.; Narise, T.; Yamazaki, T.; Ohnishi, O.; Kurokawa, S.; Ishikawa, K.; Doi, T. Quantitative evaluation of slurry flow behavior using digital image processing. Trans. Jpn. Soc. Mech. Eng. Ser. C 2011, 77, 3891–3903. [Google Scholar] [CrossRef]
- Maki, T.; Kondo, H.; Ura, T.; Sakamaki, T. AUVnavigation with particle filter. Month. J. Inst. Industrial Sci. 2004, 56, 429–433. [Google Scholar]
- Eriguchi, Y.; Ishii, K.; Watanabe, K. An underwater sound source localization system using probabilistic methods. Dyn. Des. Conf. 2009, 11, 244–247. [Google Scholar]
- Tajiri, T.; Takada, Y.; Takada, M.; Kawai, T. Movement control including localization for a wheeled mobile robot. In Proceedings of the 16th Asia Pacific Symposium on Intelligent and Evolutionary Systems, Kyoto, Japan, 13–14 December 2012; pp. 3–6.
- Gray, J. Studies in Animal Locomotion, VI. The Propulsive Power of the Dolphin. J. Exp. Biol. 1935, 13, 192–199. [Google Scholar]
- Lighthill, M.J. Note on the swimming of slender fish. J. Fluid Mech. 1960, 9, 305–317. [Google Scholar] [CrossRef]
- Lighthill, M.J. Aquatic animal propulsion of high hydrodynamical efficiency. J. Fluid Mech. 1970, 44, 265–301. [Google Scholar] [CrossRef]
- Nagai, M.; Teruya, I.; Uechi, K.; Miyazato, T. Study on an oscillating wing propulsion mechanism. Trans. JSME, Ser. B 1996, 62, 200–206. [Google Scholar] [CrossRef]
© 2014 by the authors; licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution license (http://creativecommons.org/licenses/by/3.0/).
Share and Cite
Takada, Y.; Koyama, K.; Usami, T. Position Estimation of Small Robotic Fish Based on Camera Information and Gyro Sensors. Robotics 2014, 3, 149-162. https://doi.org/10.3390/robotics3020149
Takada Y, Koyama K, Usami T. Position Estimation of Small Robotic Fish Based on Camera Information and Gyro Sensors. Robotics. 2014; 3(2):149-162. https://doi.org/10.3390/robotics3020149
Chicago/Turabian StyleTakada, Yogo, Keisuke Koyama, and Takahiro Usami. 2014. "Position Estimation of Small Robotic Fish Based on Camera Information and Gyro Sensors" Robotics 3, no. 2: 149-162. https://doi.org/10.3390/robotics3020149
APA StyleTakada, Y., Koyama, K., & Usami, T. (2014). Position Estimation of Small Robotic Fish Based on Camera Information and Gyro Sensors. Robotics, 3(2), 149-162. https://doi.org/10.3390/robotics3020149