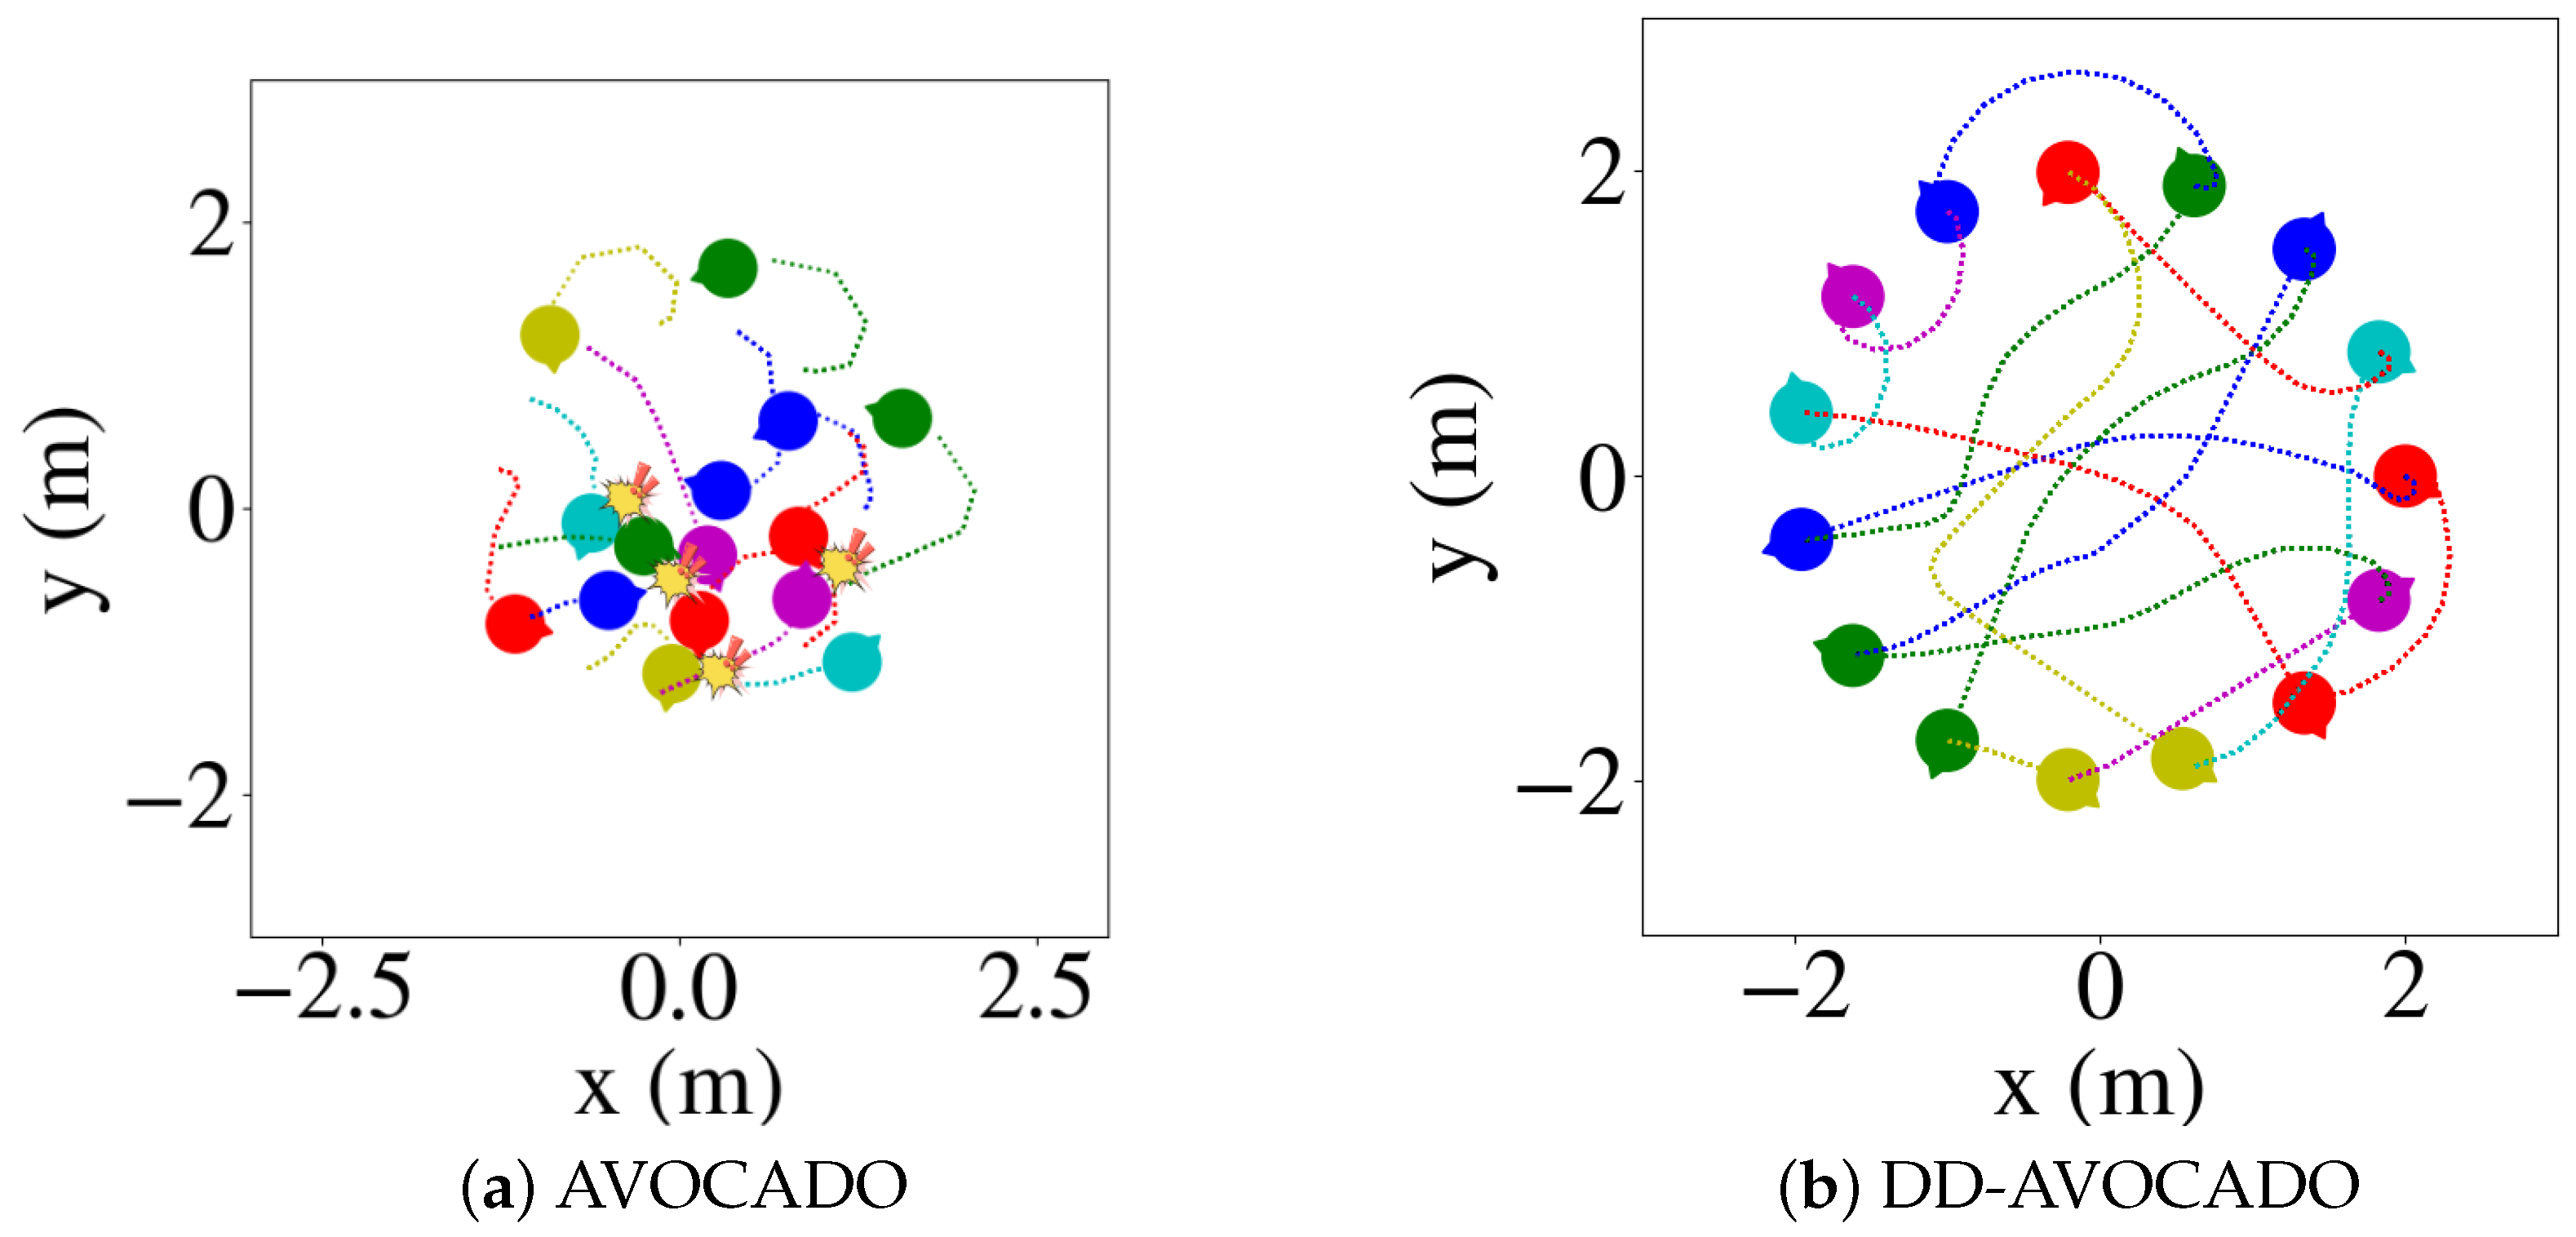
Adaptive Optimal Collision Avoidance of Dynamic Agents for Differential-Drive Robots


Abstract
1. Introduction
- Incorporation of non-holonomic feasibility into AVOCADO. We restrict the holonomic velocity space of AVOCADO to an admissible set that accounts for the tracking error of a differential-drive controller, ensuring that selected velocities are physically executable.
- Tracking-error-aware collision avoidance within the AVOCADO framework. We adapt the velocity obstacle constraints to account for tracking error while preserving AVOCADO’s adaptive cooperation mechanism, enabling safe interaction with heterogeneous agents.
- Validation in simulation and real robot experiments. We evaluate the proposed approach in both simulated and real-world scenarios, showing improved safety compared to baseline methods while maintaining effective navigation.
2. Related Work
3. Preliminaries and Problem Formulation
3.1. AVOCADO
3.2. Kinematic Model
- Region : .
- Region : .
- Region : .
3.3. Problem Formulation
4. Method
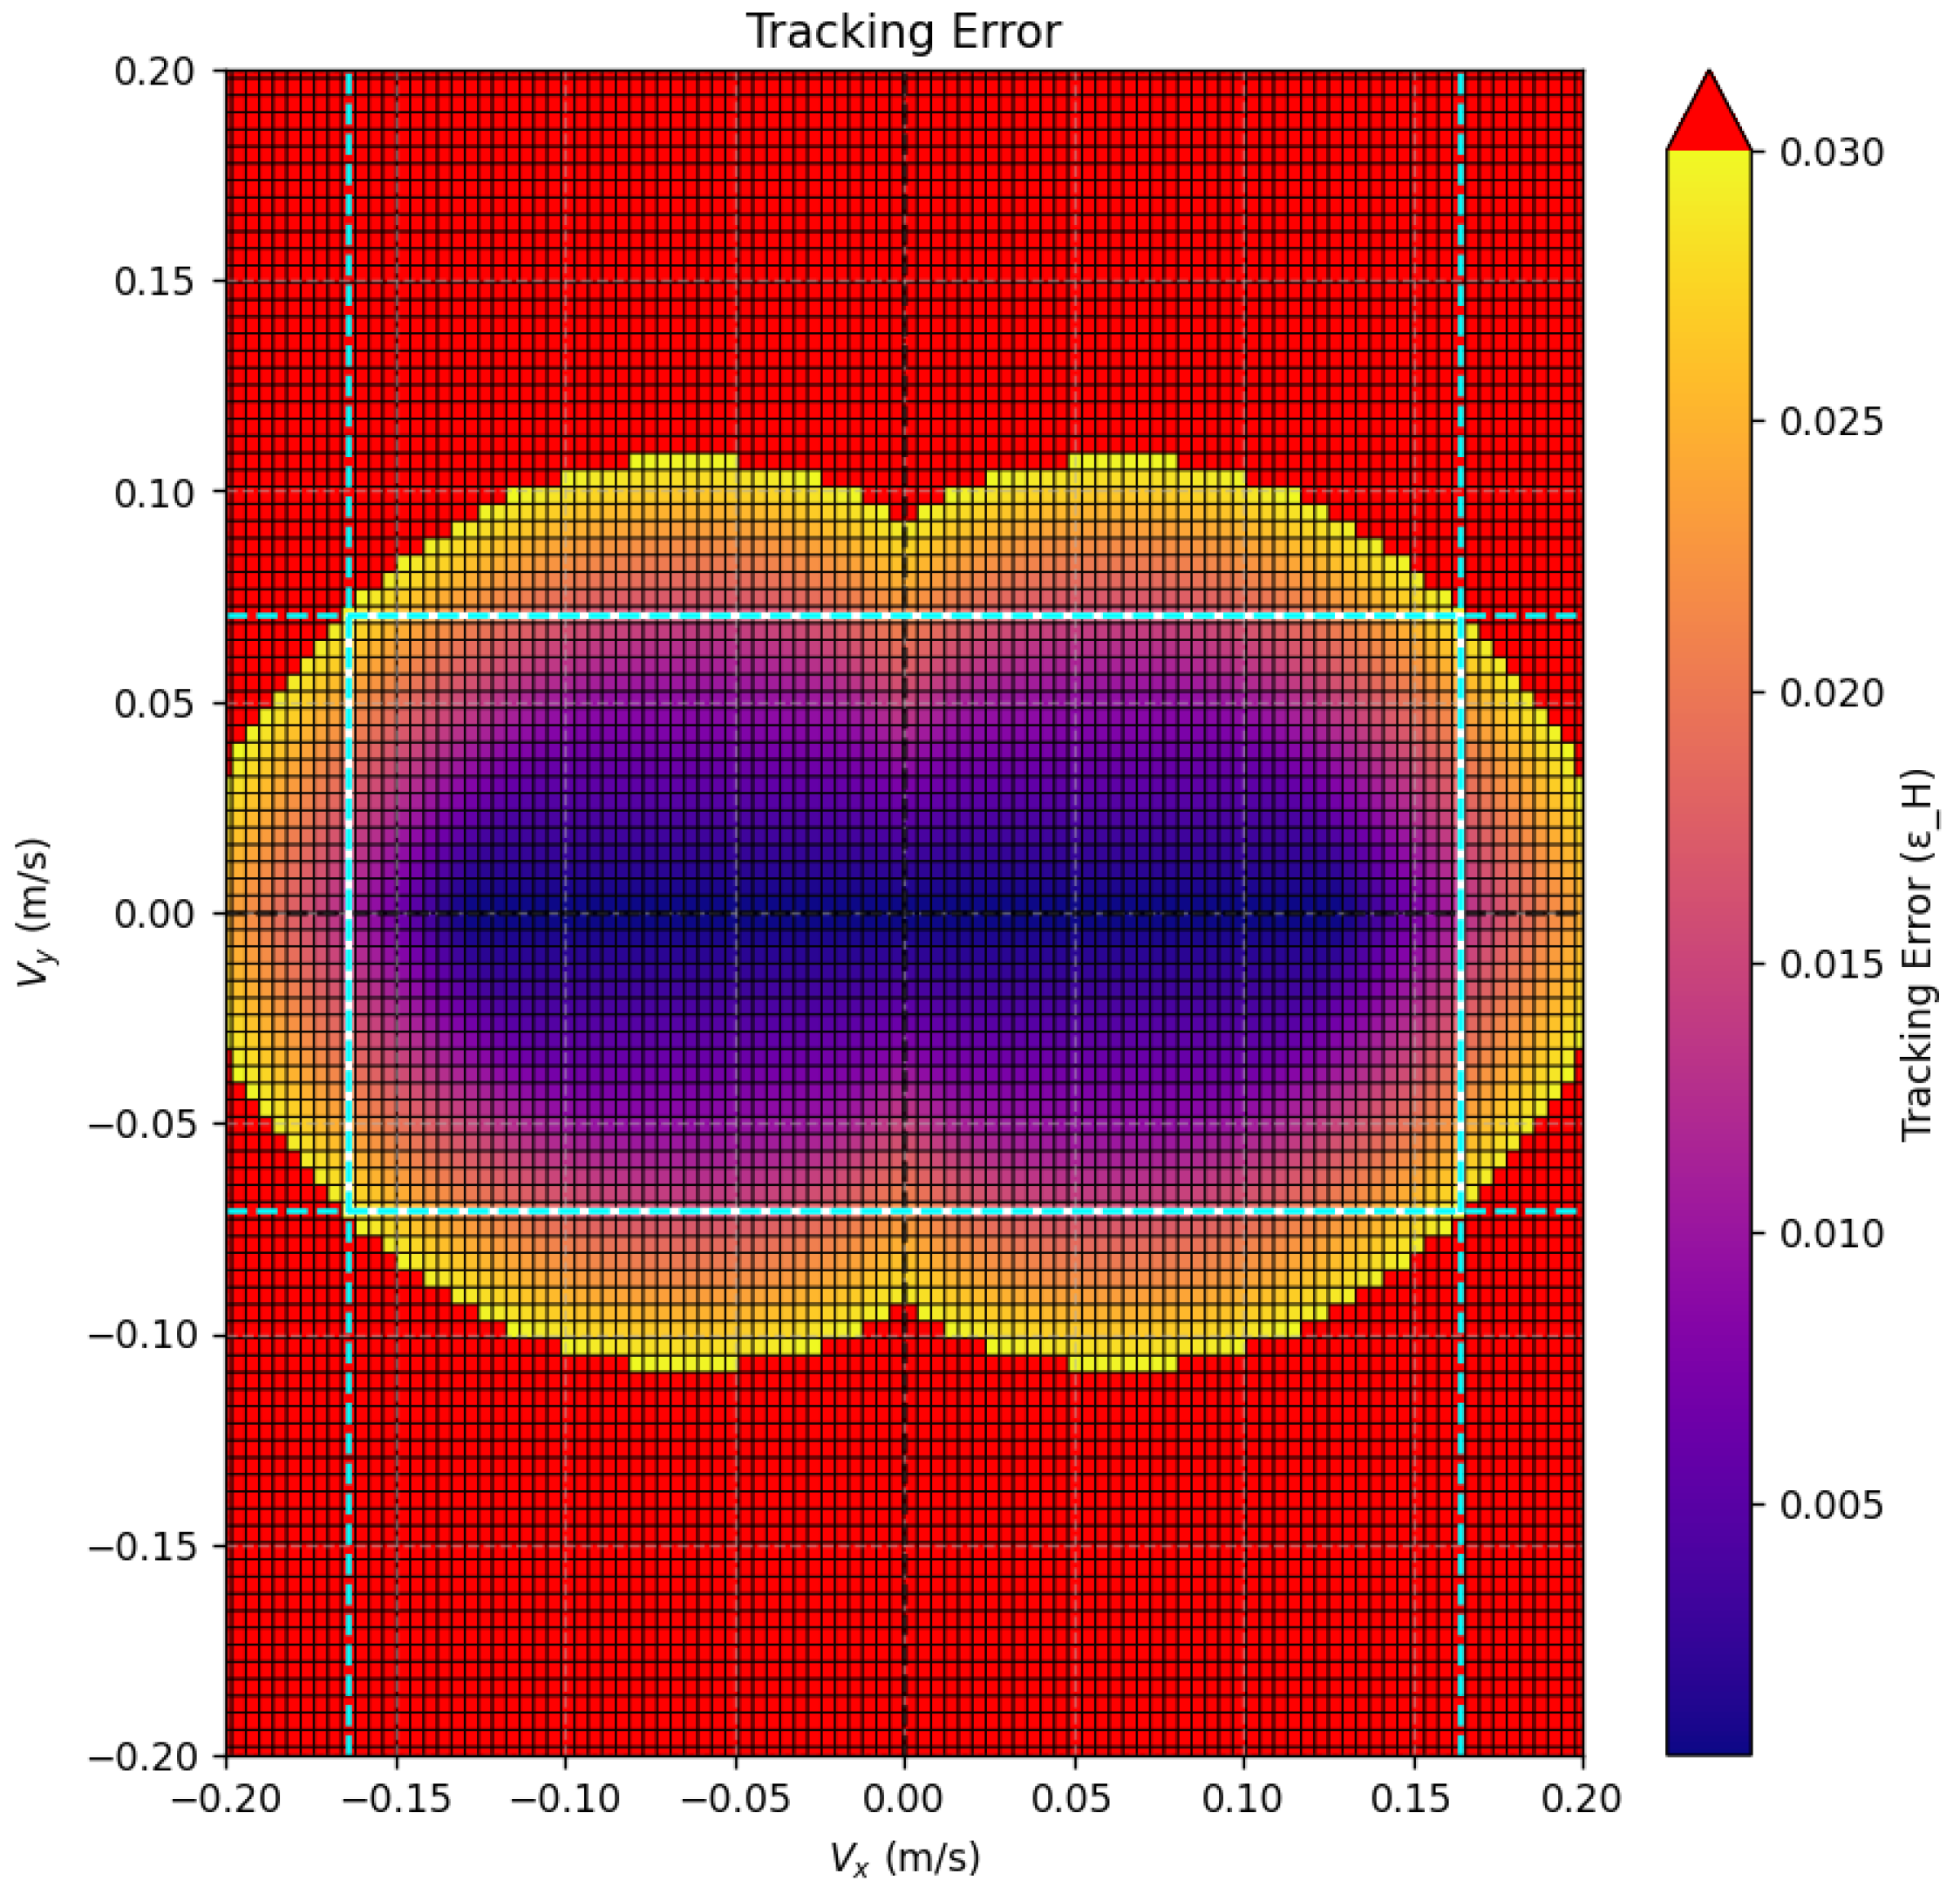
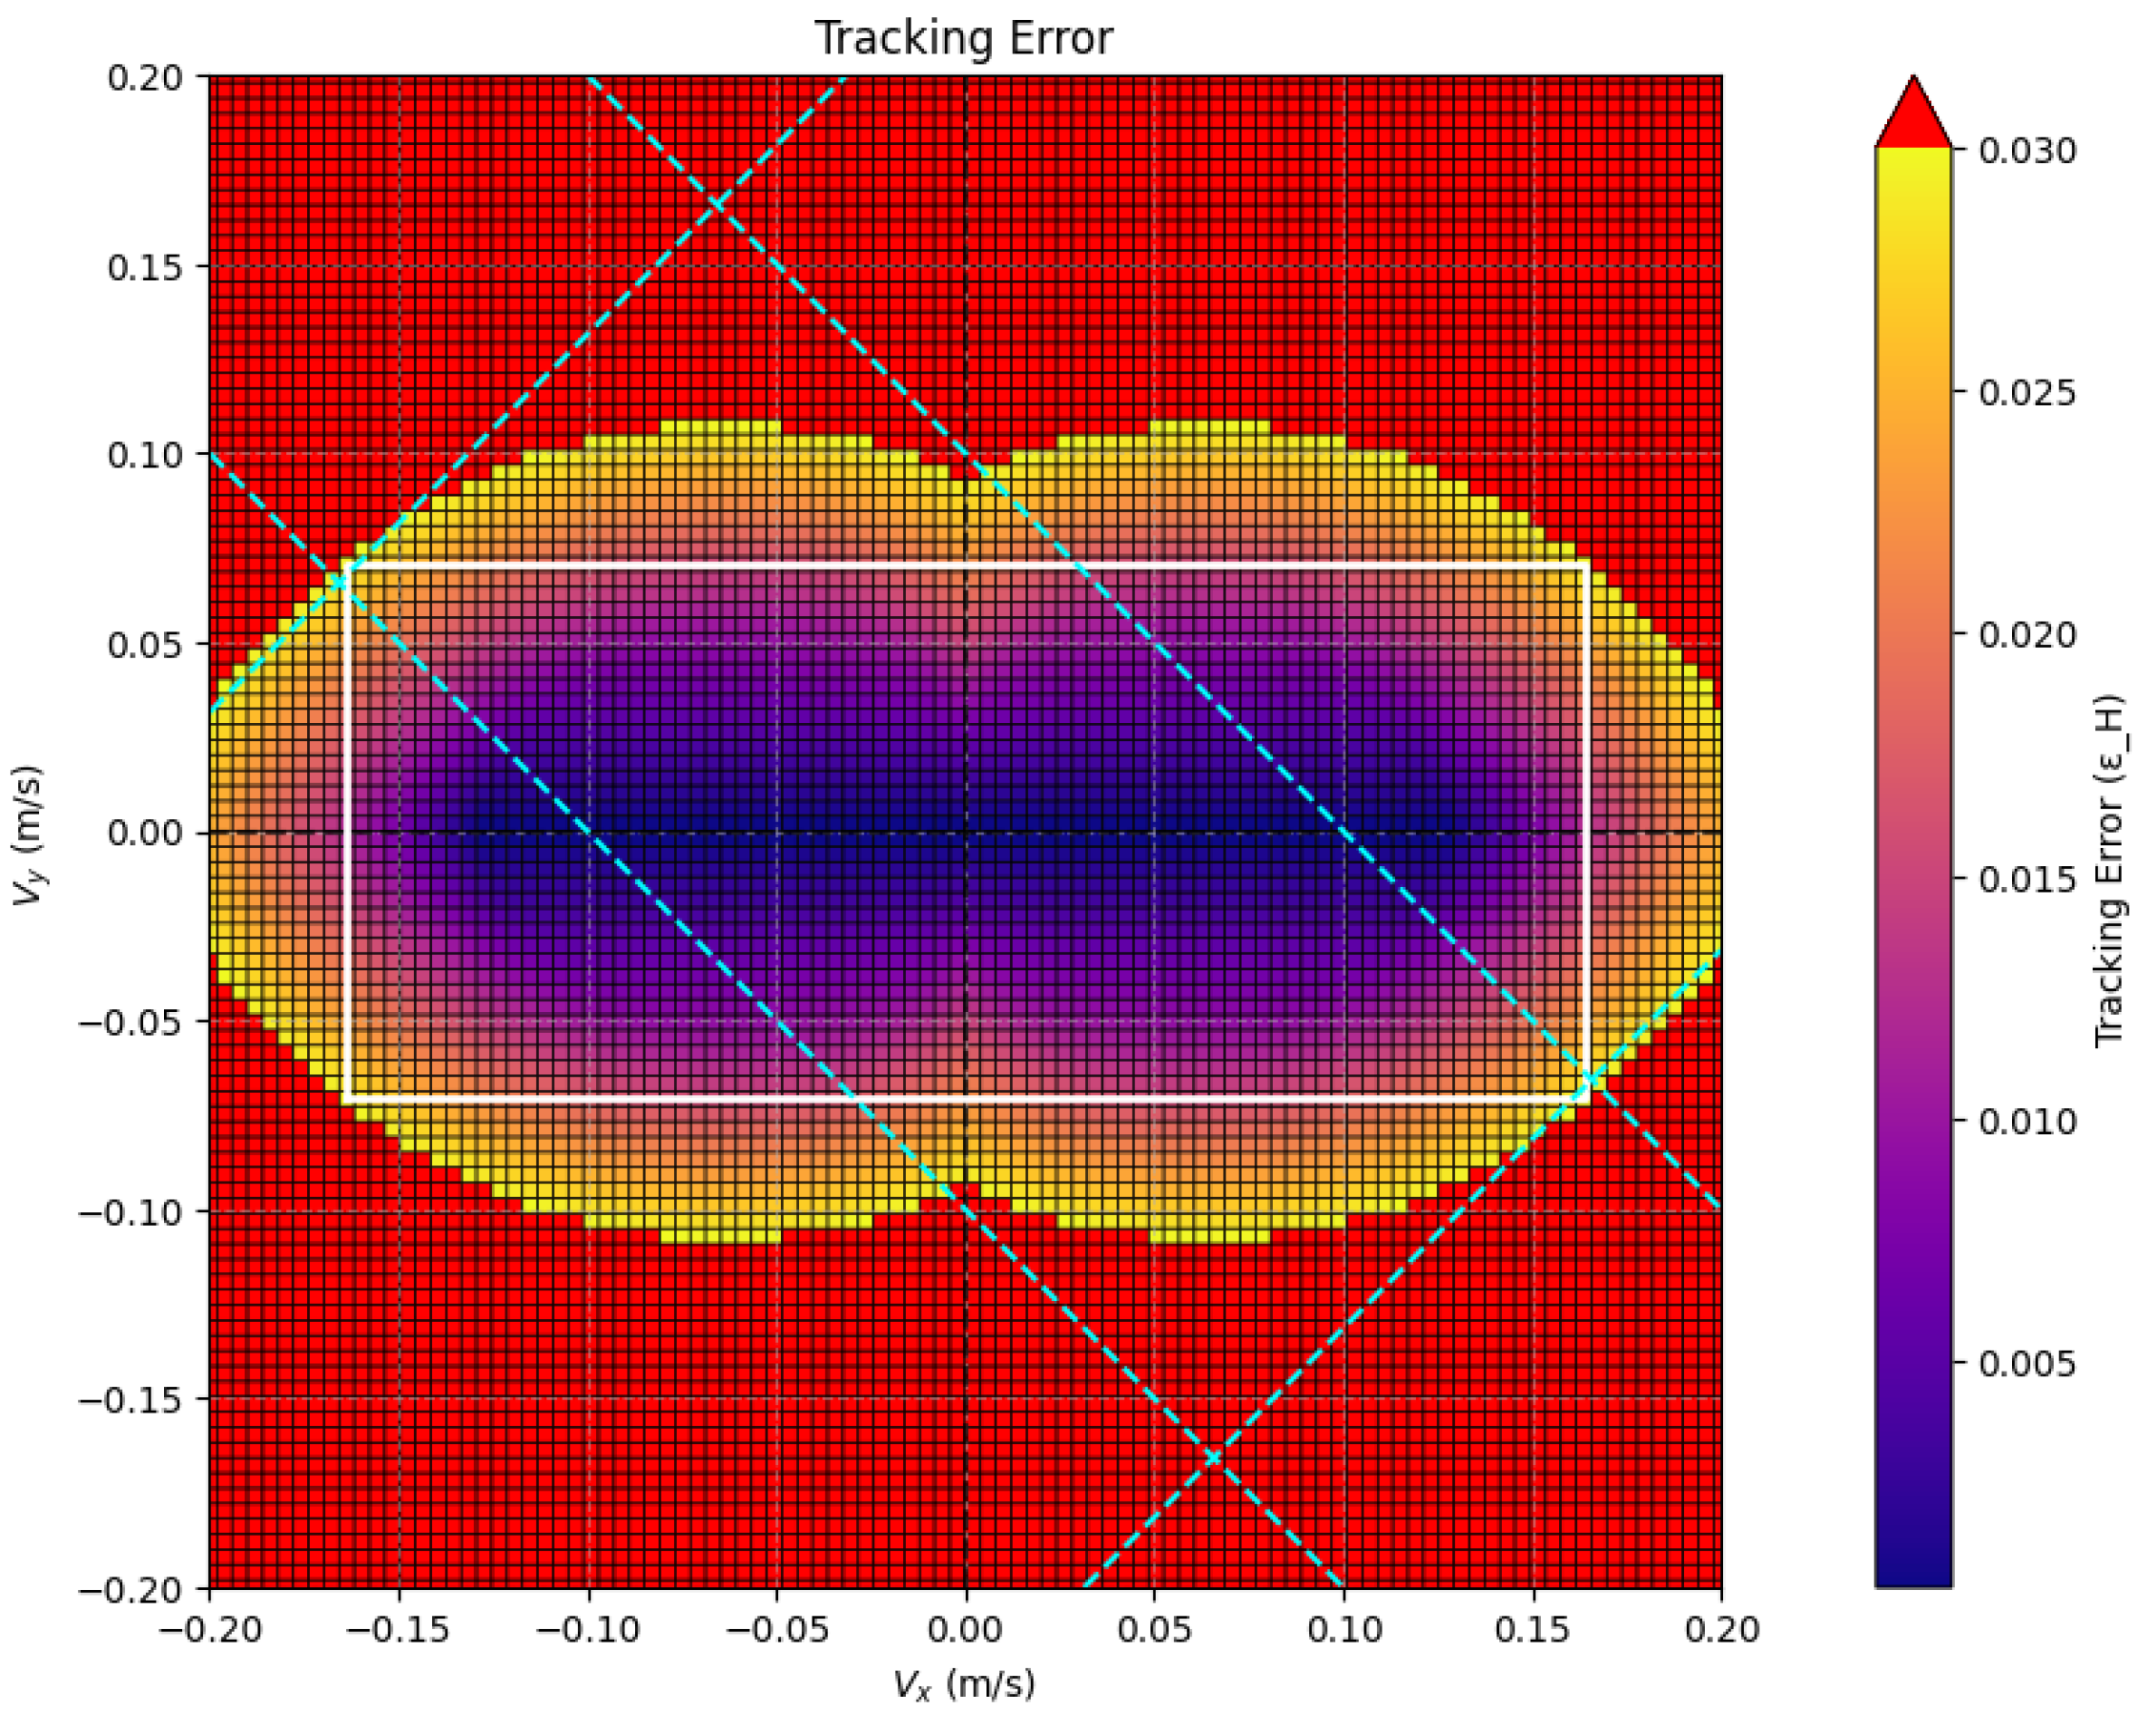
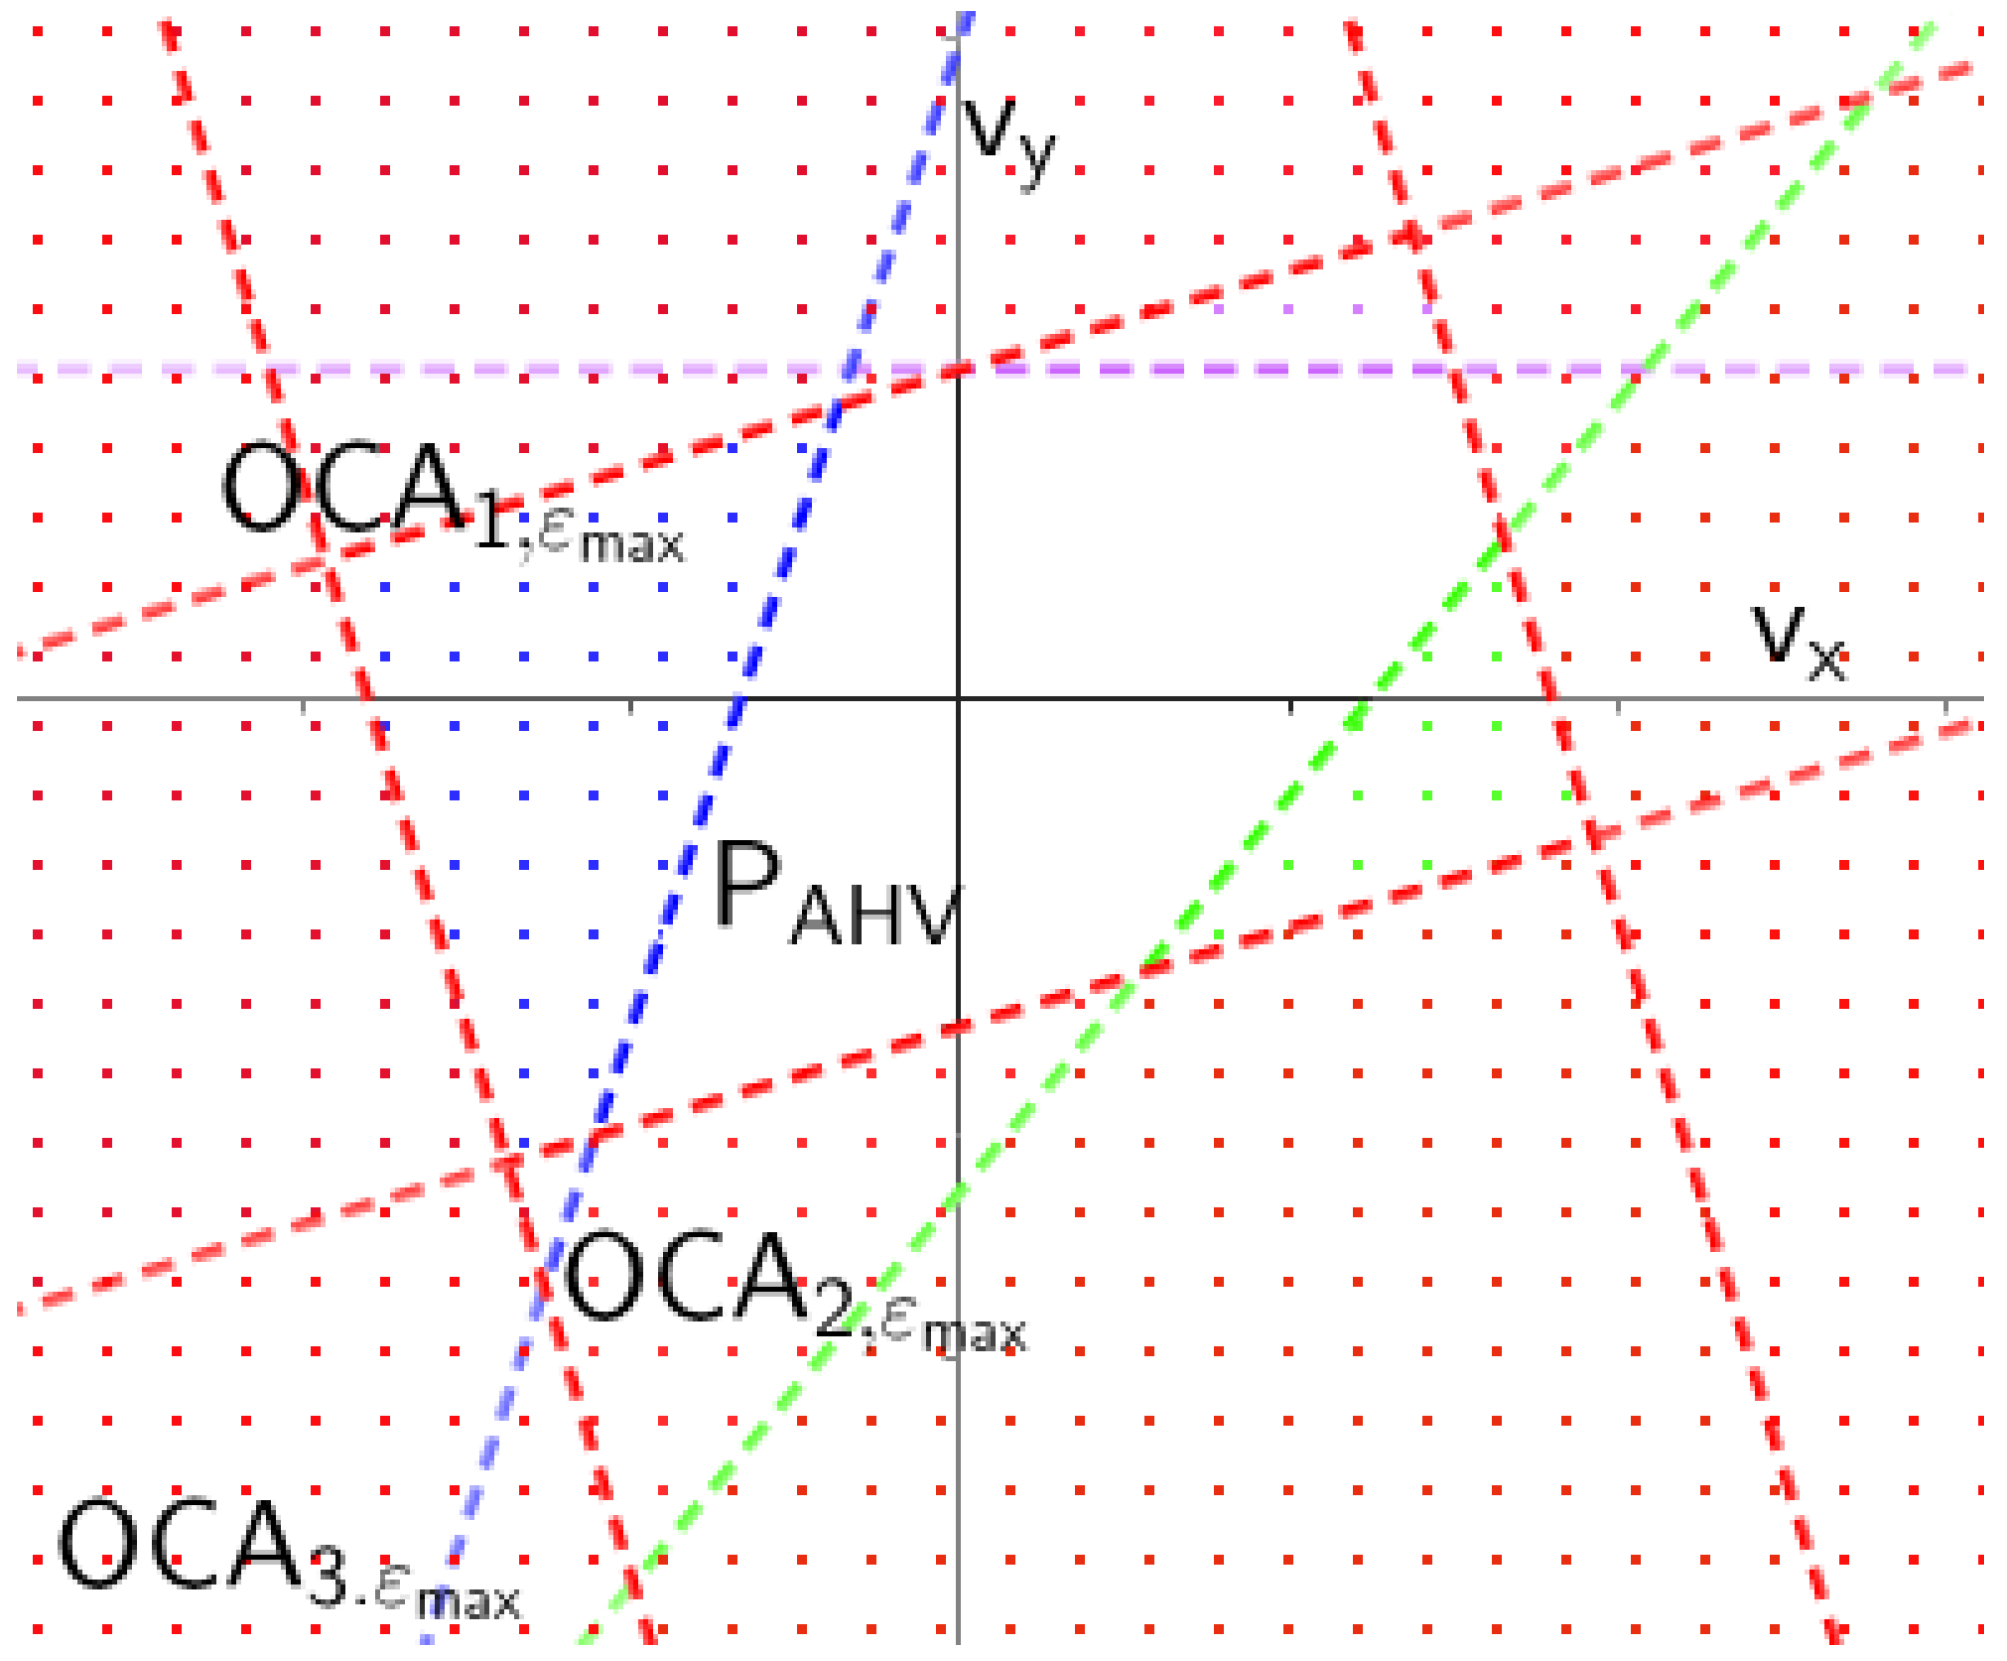
4.1. Admissible Velocity Set
4.2. Integration into AVOCADO Logic

5. Experiments
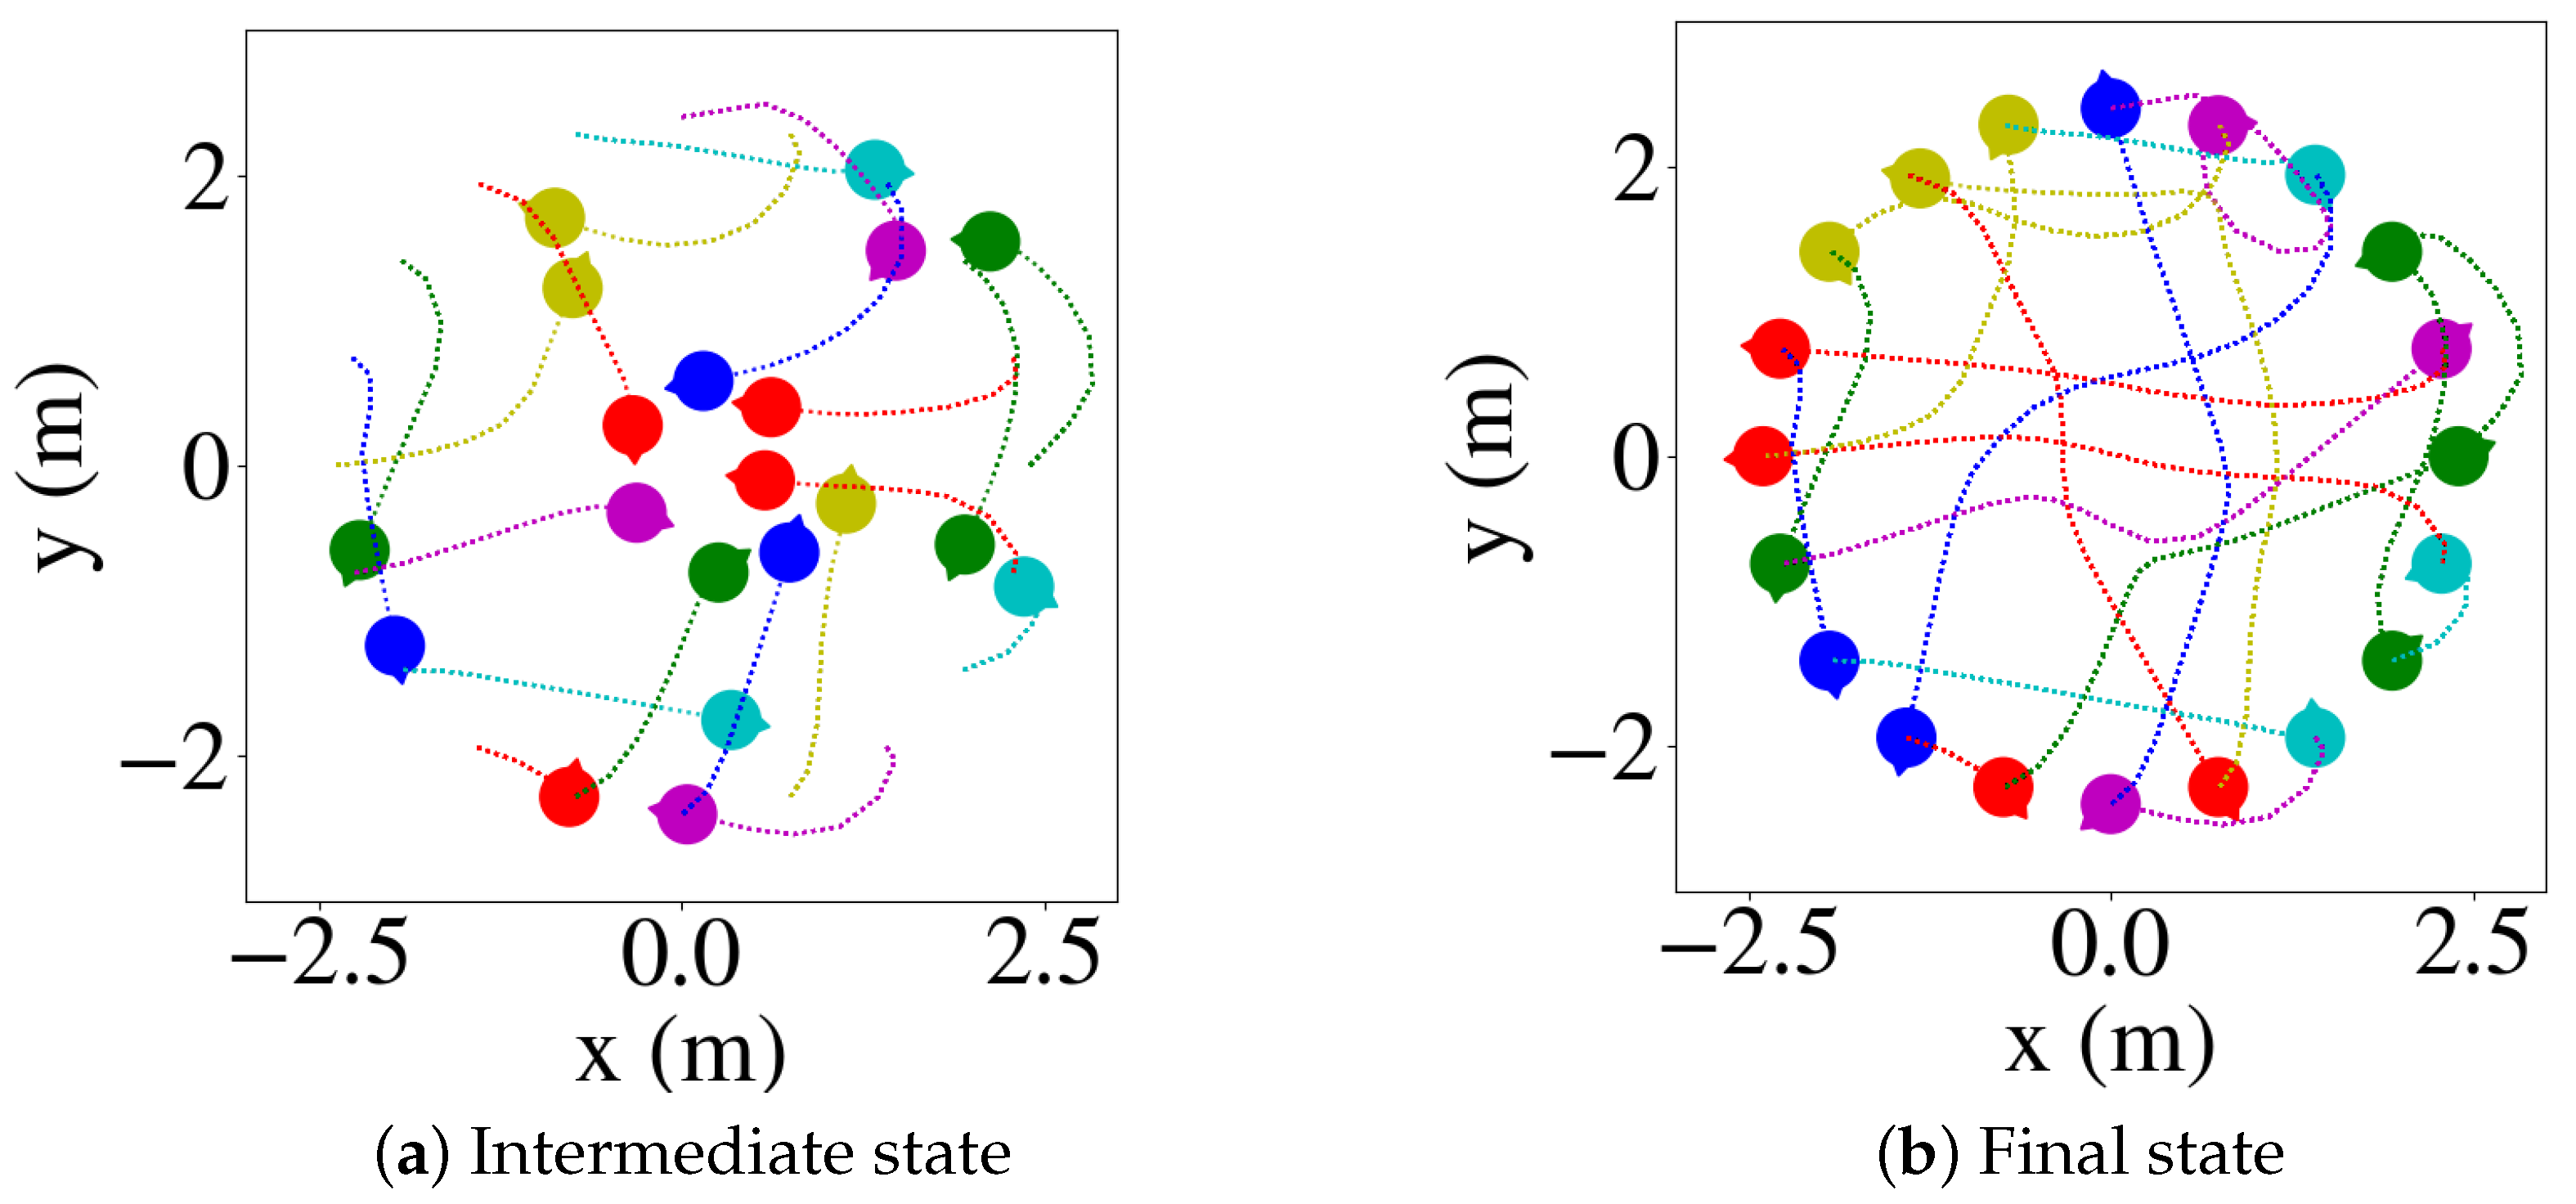
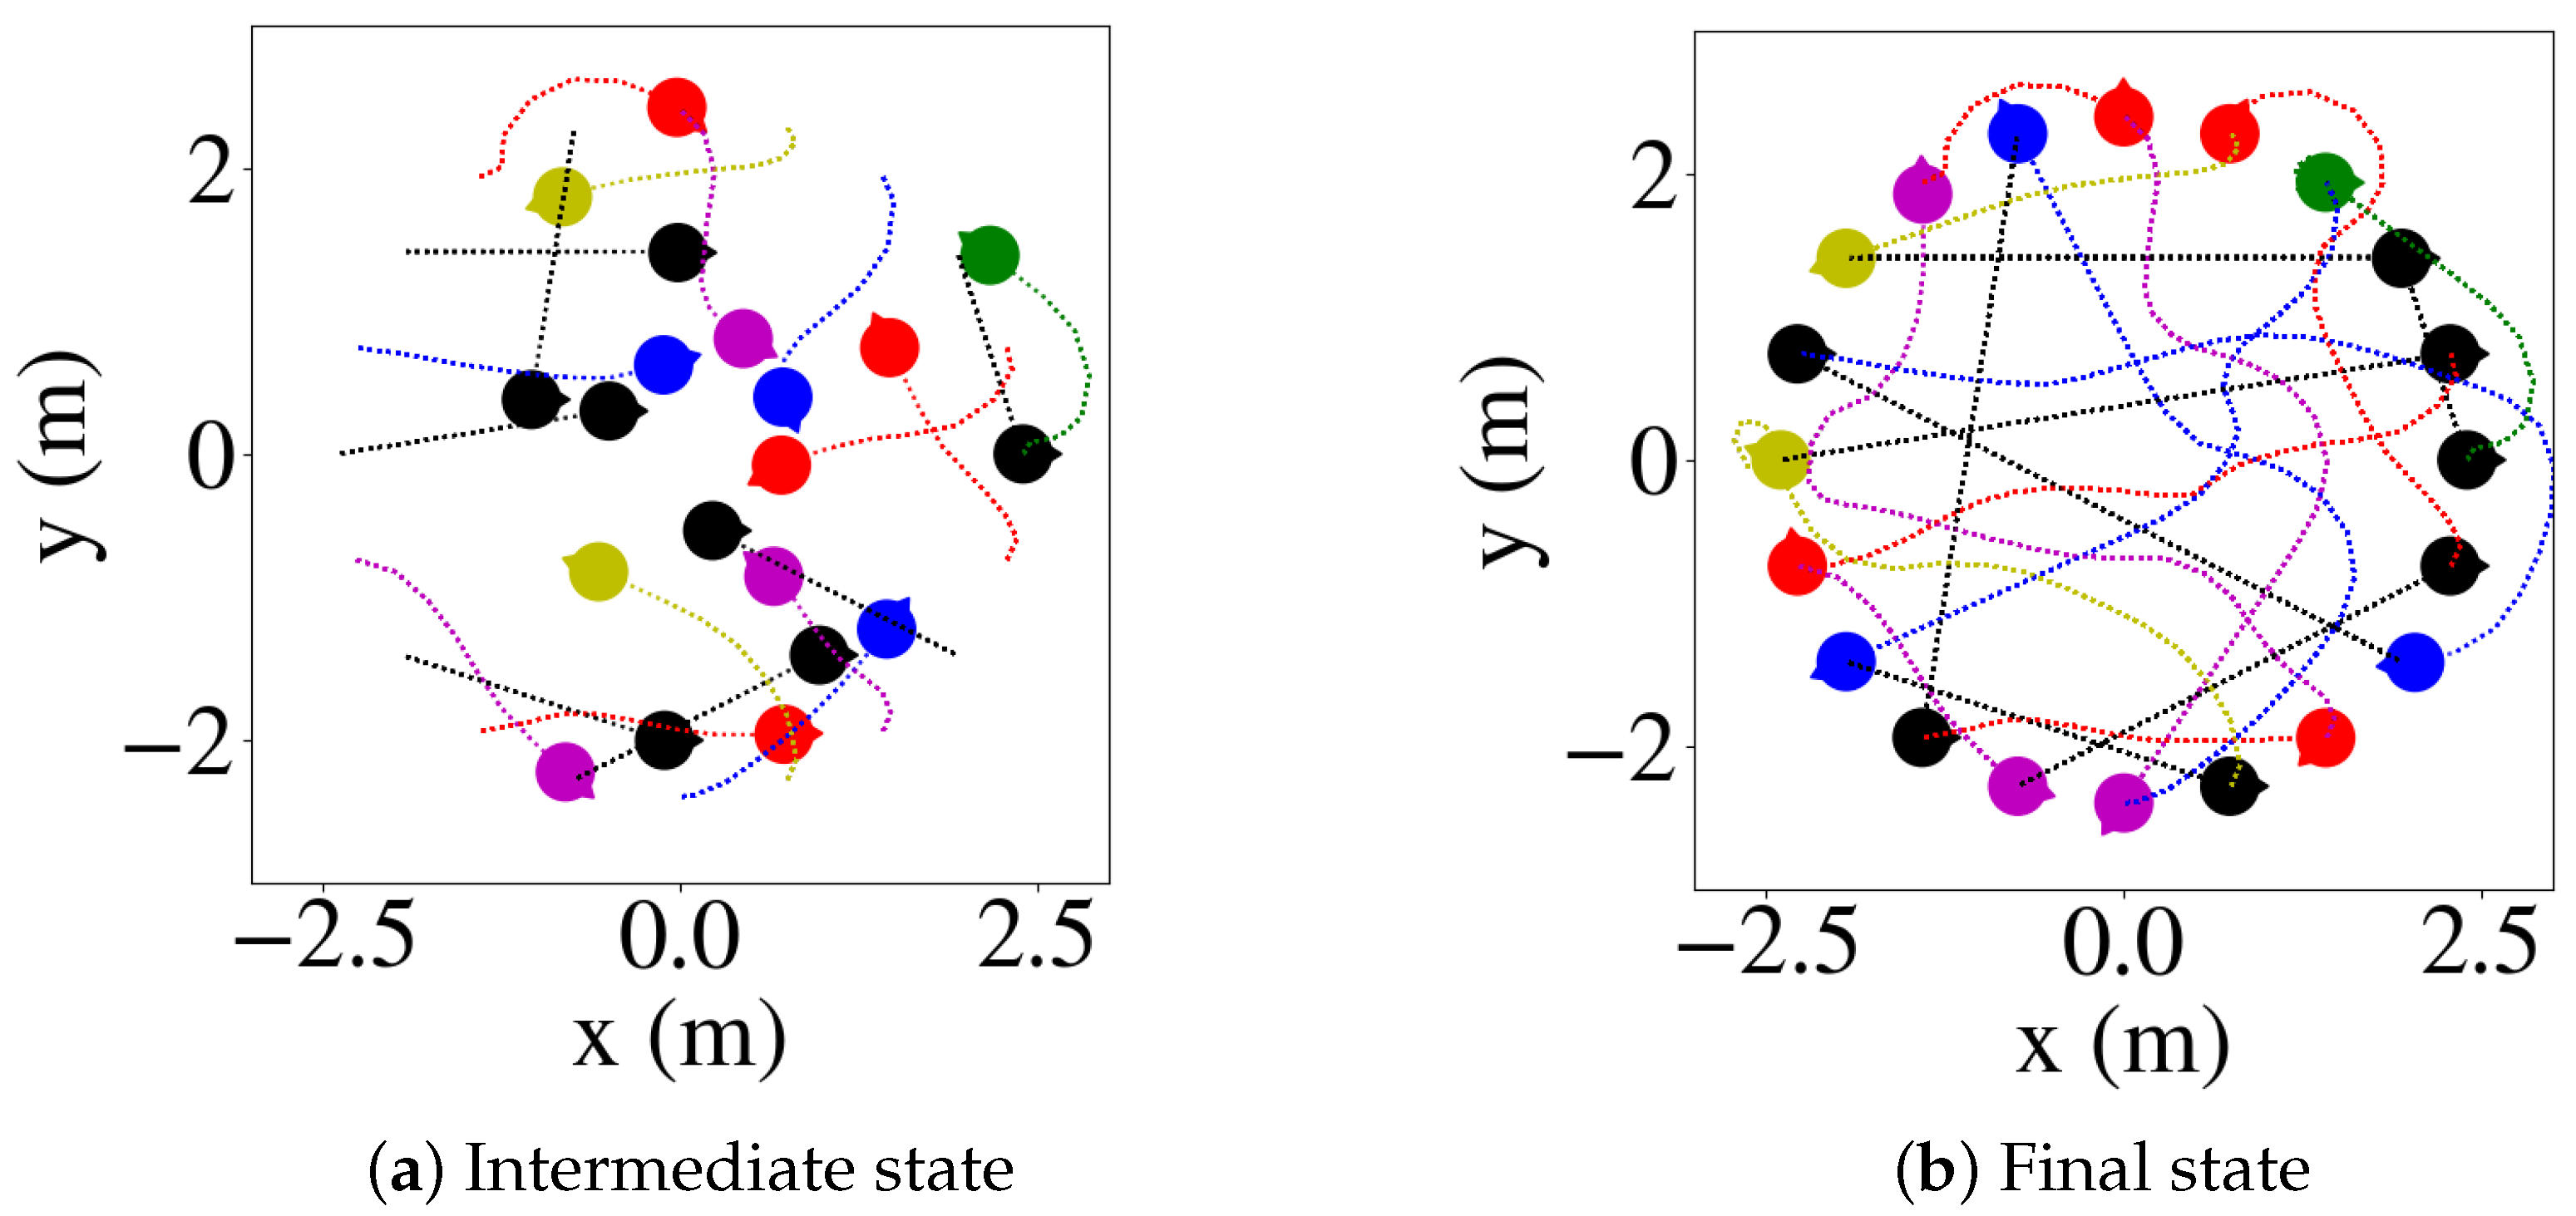
5.1. Qualitative Results
5.2. Simulation Setup
5.3. Quantitative Results
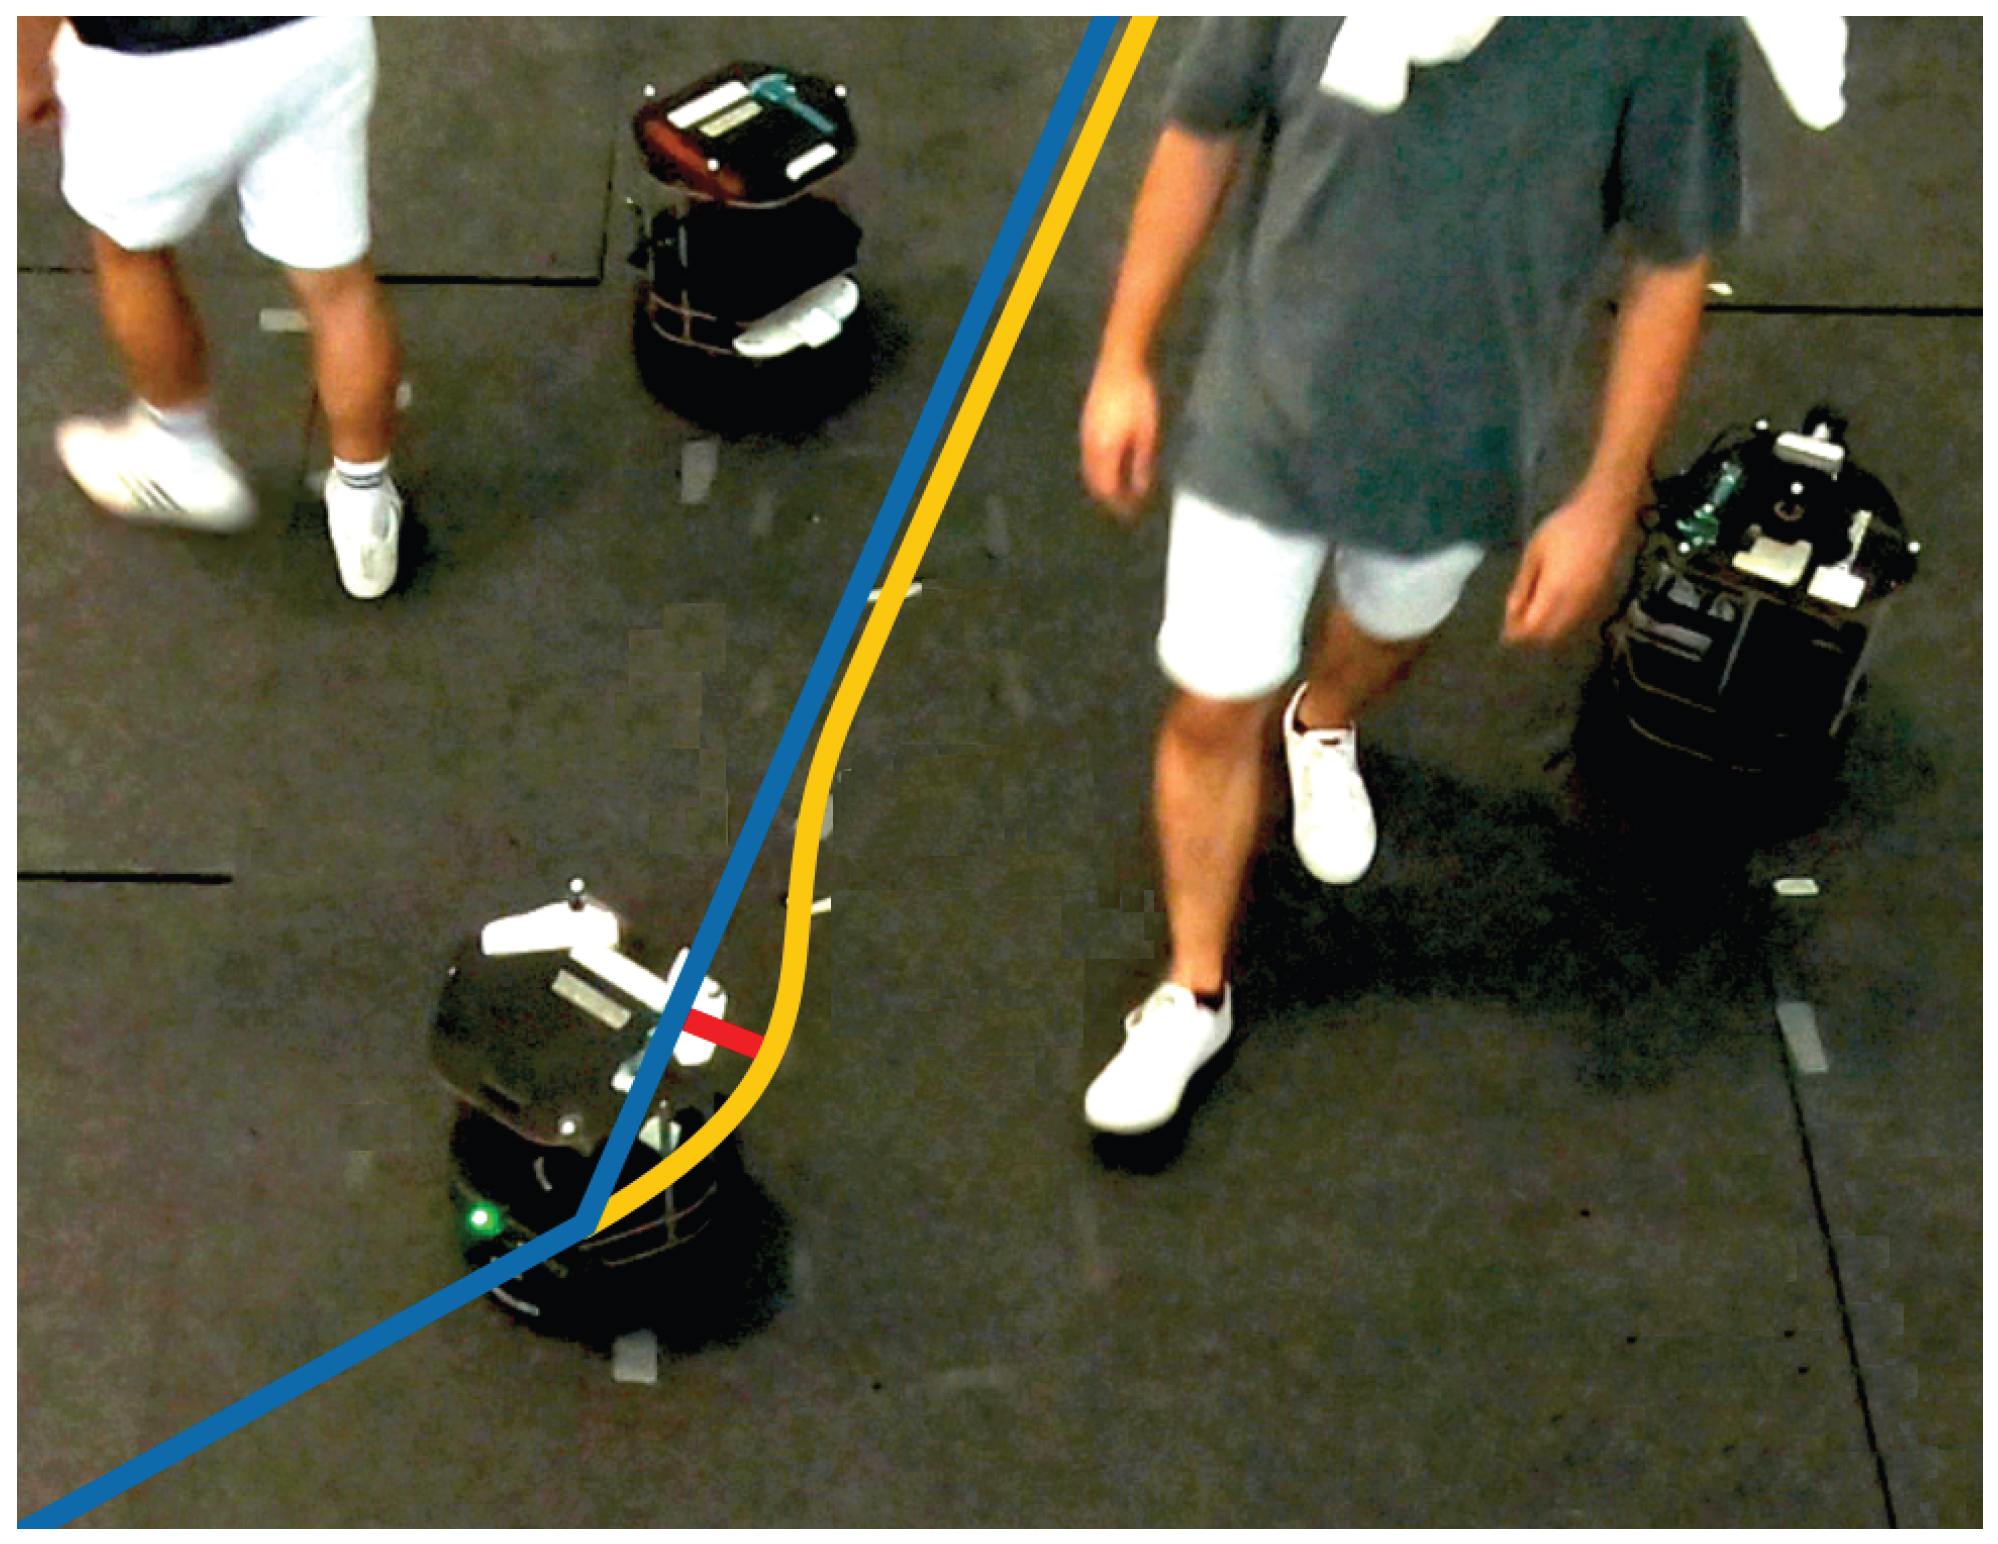
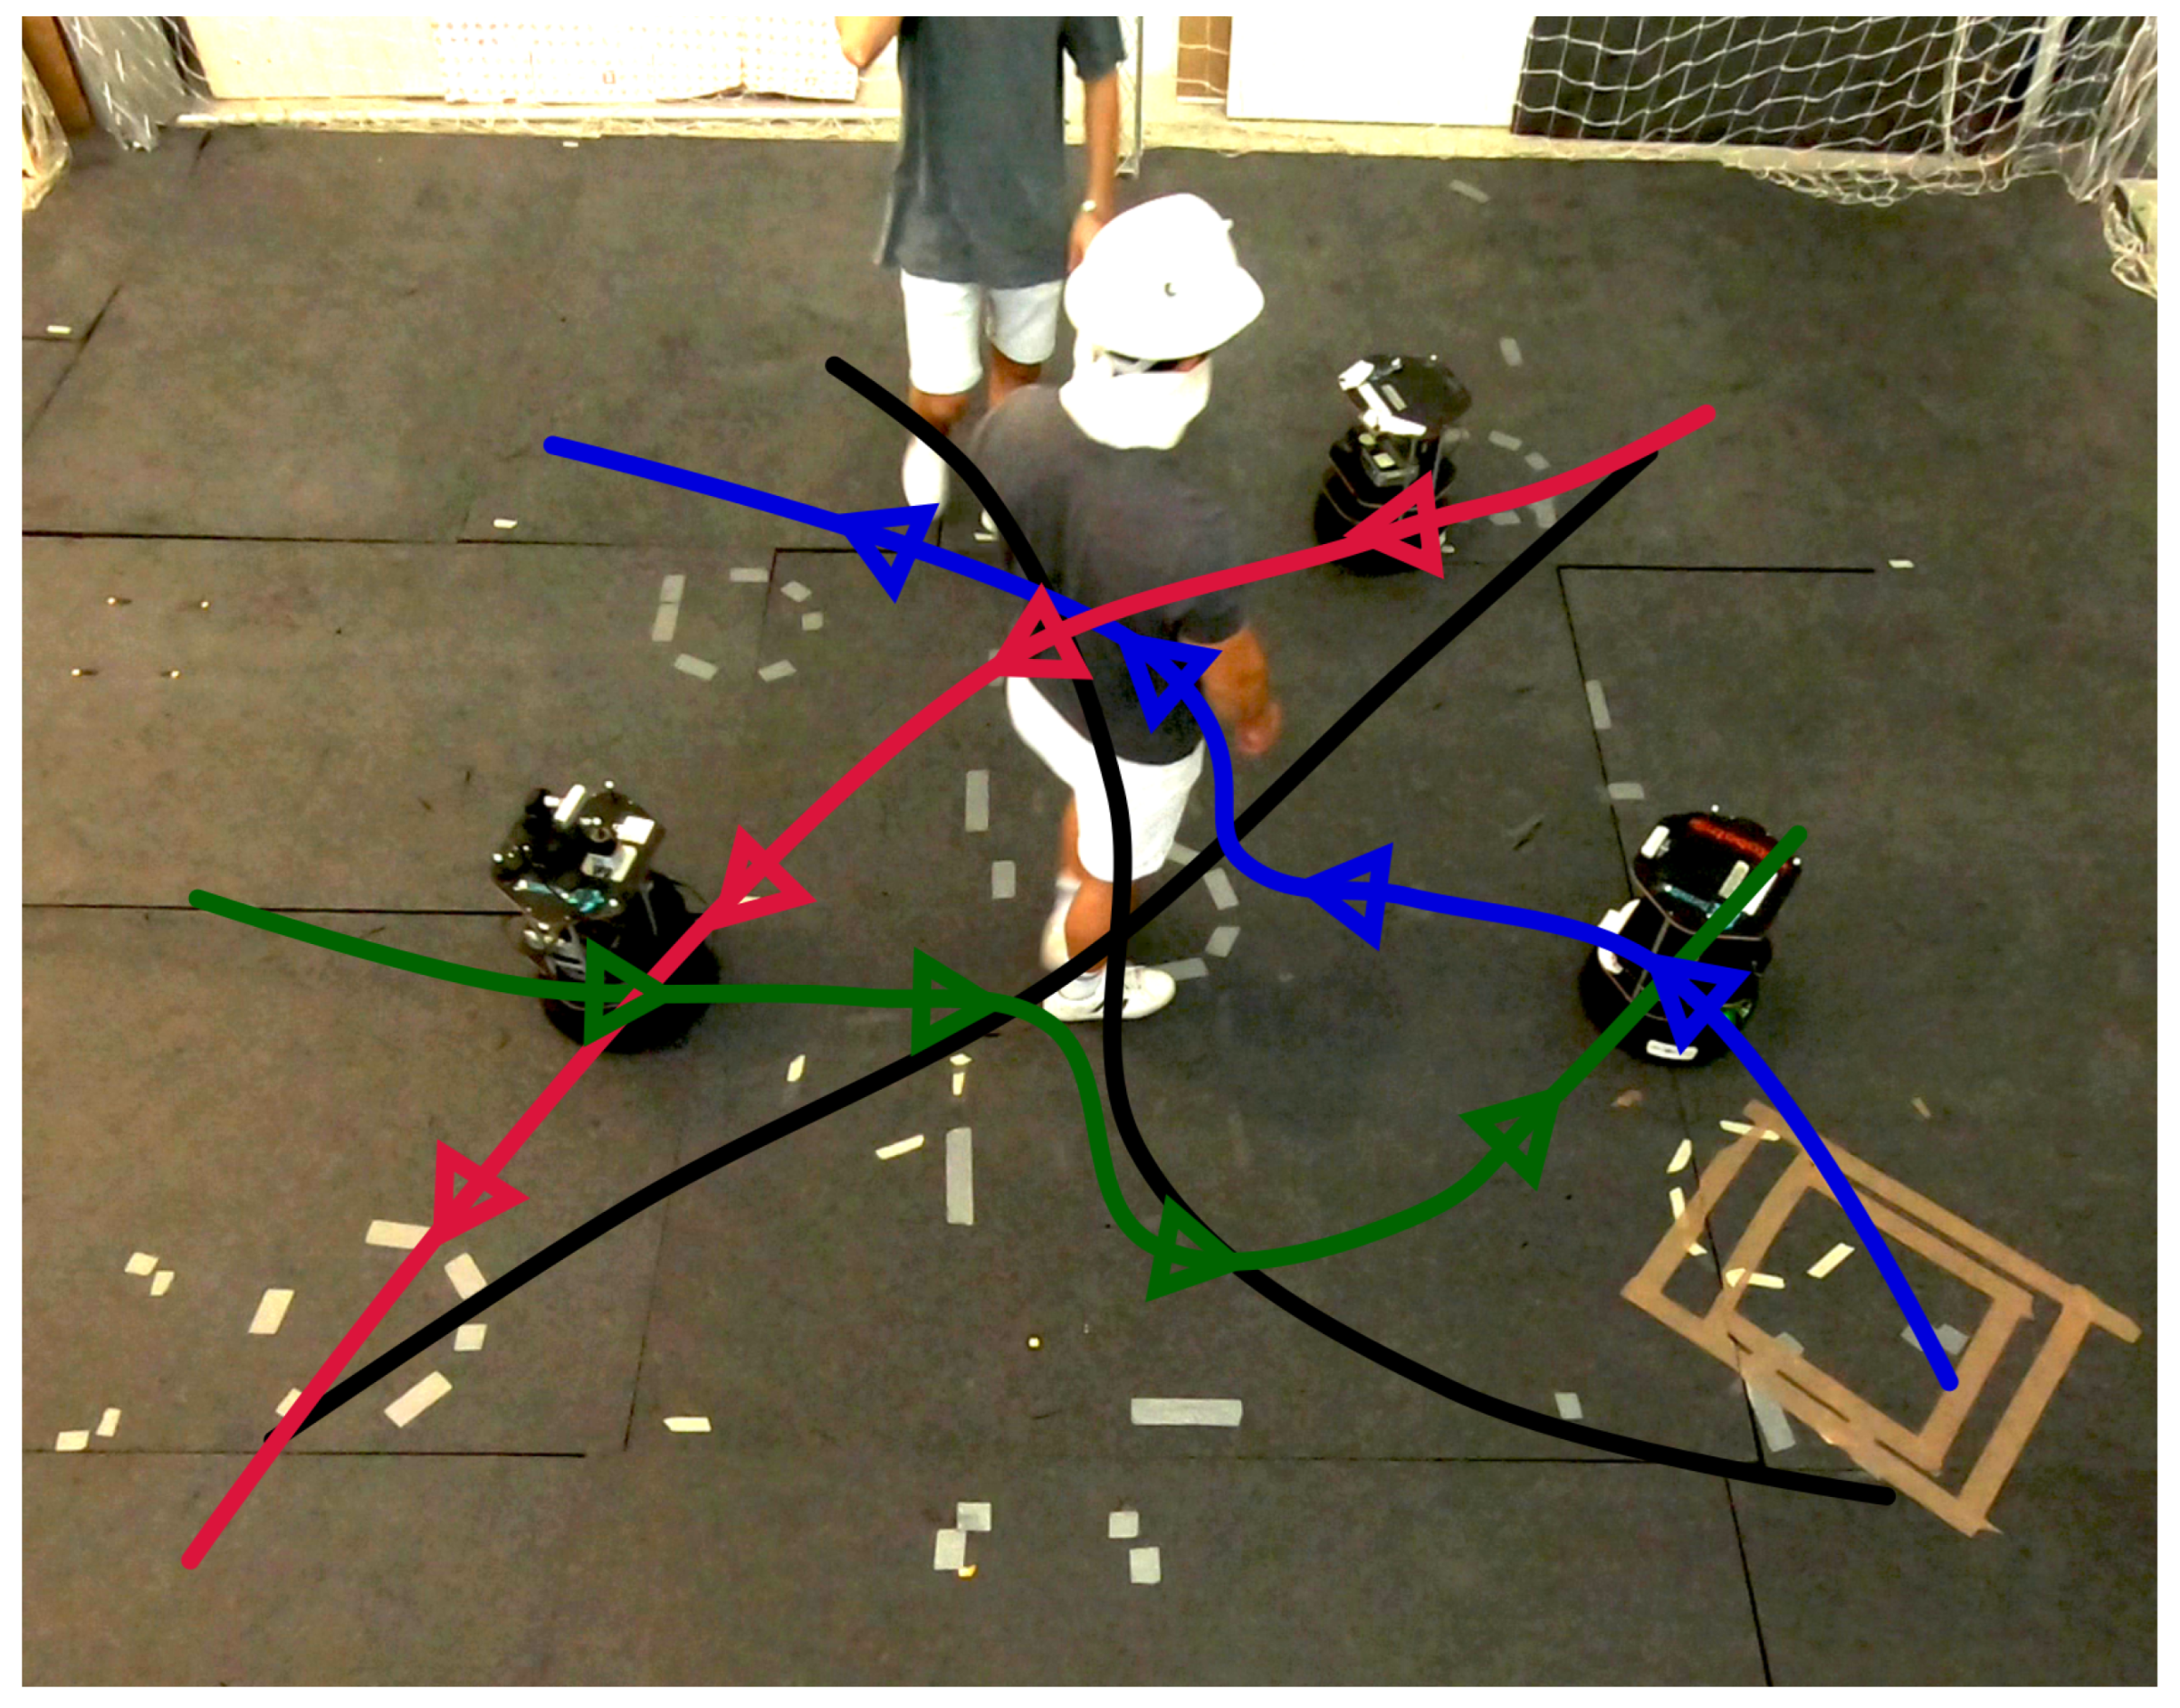
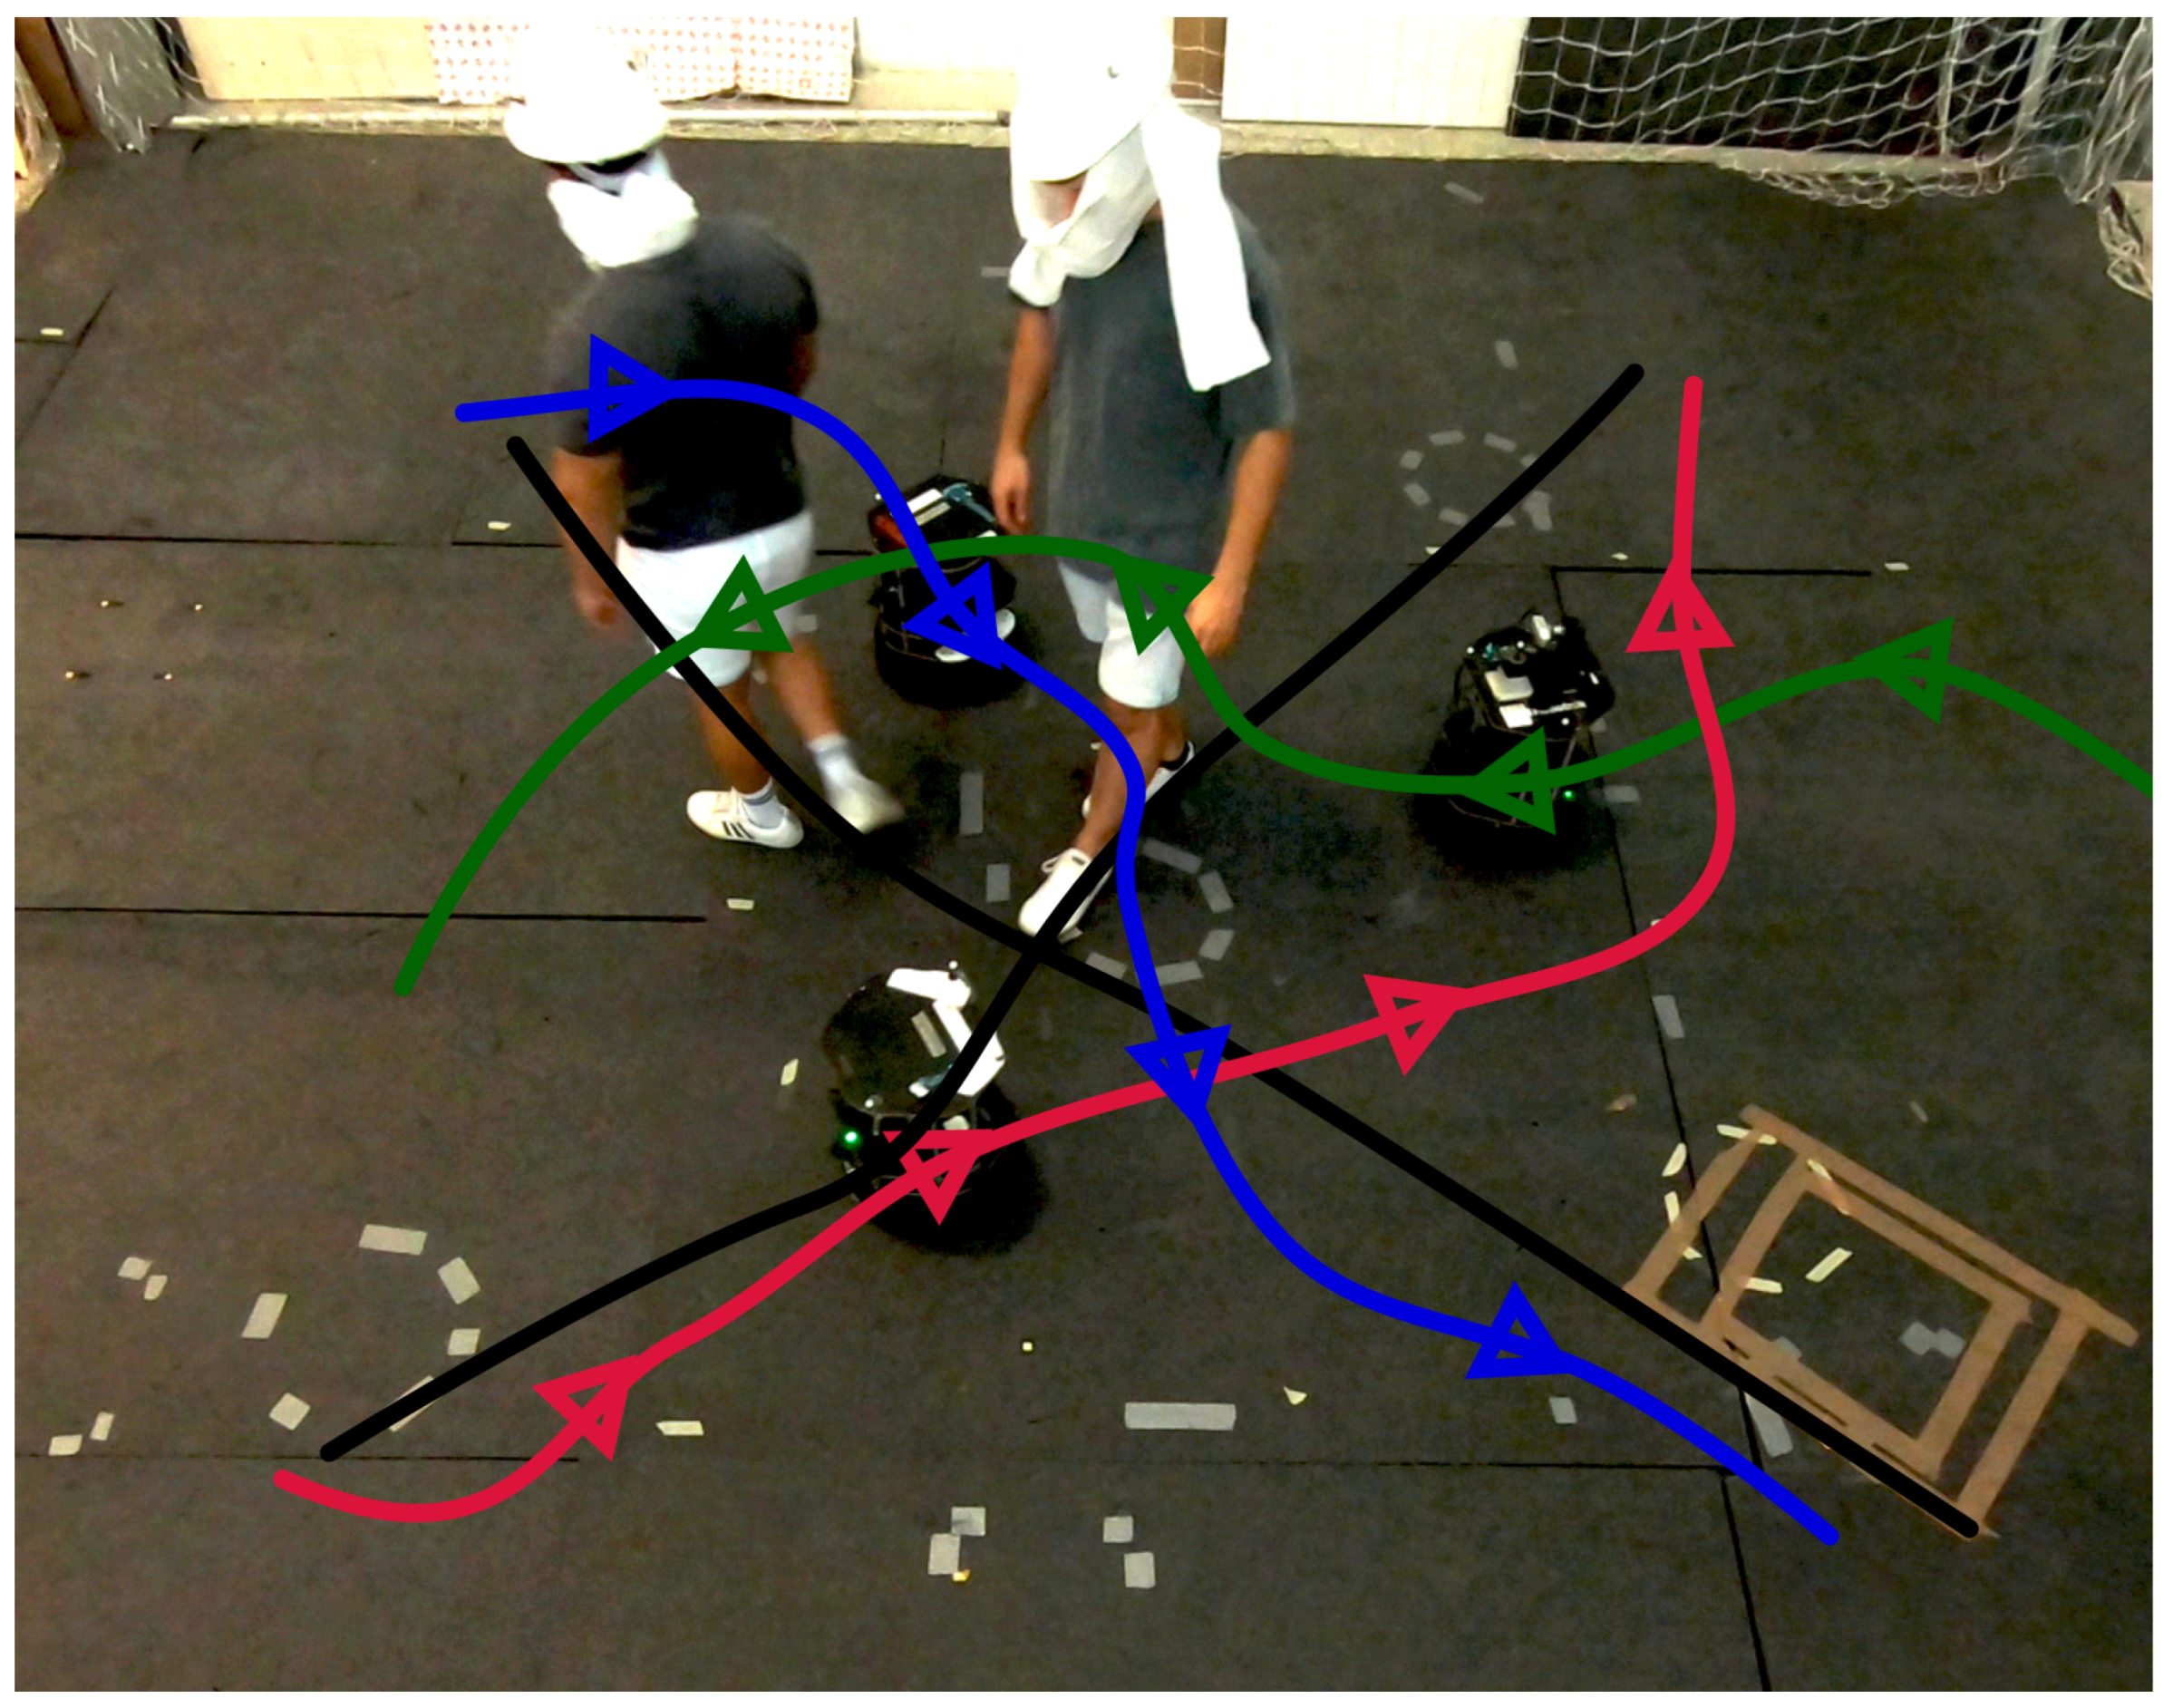
5.4. Hardware Experiments
6. Conclusions
Author Contributions
Funding
Informed Consent Statement
Data Availability Statement
Conflicts of Interest
References
- Fiorini, P.; Shiller, Z. Motion planning in dynamic environments using velocity obstacles. Int. J. Robot. Res. 1998, 17, 760–772. [Google Scholar] [CrossRef] [Scilit]
- Van Den Berg, J.; Guy, S.J.; Lin, M.; Manocha, D. Reciprocal n-body collision avoidance. In Robotics Research: The 14th International Symposium ISRR; Springer: Berlin/Heidelberg, Germany, 2011; pp. 3–19. [Google Scholar]
- Martinez-Baselga, D.; Sebastián, E.; Montijano, E.; Riazuelo, L.; Sagüés, C.; Montano, L. AVOCADO: Adaptive Optimal Collision Avoidance Driven by Opinion. IEEE Trans. Robot. 2025, 41, 2495–2511. [Google Scholar] [CrossRef] [Scilit]
- Alonso-Mora, J.; Beardsley, P.; Siegwart, R. Cooperative collision avoidance for nonholonomic robots. IEEE Trans. Robot. 2018, 34, 404–420. [Google Scholar] [CrossRef] [Scilit]
- Fox, D.; Burgard, W.; Thrun, S. The dynamic window approach to collision avoidance. IEEE Robot. Autom. Mag. 2002, 4, 23–33. [Google Scholar] [CrossRef] [Scilit]
- Khatib, O. Real-time obstacle avoidance for manipulators and mobile robots. Int. J. Robot. Res. 1986, 5, 90–98. [Google Scholar] [CrossRef] [Scilit]
- Helbing, D.; Molnar, P. Social force model for pedestrian dynamics. Phys. Rev. E 1995, 51, 4282. [Google Scholar] [CrossRef] [Scilit]
- Vesentini, F.; Muradore, R.; Fiorini, P. A survey on velocity obstacle paradigm. Robot. Auton. Syst. 2024, 174, 104645. [Google Scholar] [CrossRef] [Scilit]
- Van den Berg, J.; Lin, M.; Manocha, D. Reciprocal velocity obstacles for real-time multi-agent navigation. In 2008 IEEE International Conference on Robotics and Automation; IEEE: Piscataway, NJ, USA, 2008; pp. 1928–1935. [Google Scholar]
- Guo, K.; Wang, D.; Fan, T.; Pan, J. VR-ORCA: Variable responsibility optimal reciprocal collision avoidance. IEEE Robot. Autom. Lett. 2021, 6, 4520–4527. [Google Scholar] [CrossRef] [Scilit]
- Bizyaeva, A.; Franci, A.; Leonard, N.E. Nonlinear opinion dynamics with tunable sensitivity. IEEE Trans. Autom. Control 2022, 68, 1415–1430. [Google Scholar] [CrossRef] [Scilit]
- Leonard, N.E.; Bizyaeva, A.; Franci, A. Fast and flexible multiagent decision-making. Annu. Rev. Control Robot. Auton. Syst. 2024, 7, 19–45. [Google Scholar] [CrossRef] [Scilit]
- Cathcart, C.; Santos, M.; Park, S.; Leonard, N.E. Proactive opinion-driven robot navigation around human movers. In 2023 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS); IEEE: Piscataway, NJ, USA, 2023; pp. 4052–4058. [Google Scholar]
- Amorim, G.; Bizyaeva, A.; Franci, A.; Leonard, N.E. Spatially-Invariant Opinion Dynamics on the Circle. IEEE Control Syst. Lett. 2024, 8, 3231–3236. [Google Scholar] [CrossRef] [Scilit]
- Van Den Berg, J.; Snape, J.; Guy, S.J.; Manocha, D. Reciprocal collision avoidance with acceleration-velocity obstacles. In 2011 IEEE International Conference on Robotics and Automation; IEEE: Piscataway, NJ, USA, 2011; pp. 3475–3482. [Google Scholar]
- Rufli, M.; Alonso-Mora, J.; Siegwart, R. Reciprocal collision avoidance with motion continuity constraints. IEEE Trans. Robot. 2013, 29, 899–912. [Google Scholar] [CrossRef] [Scilit]
- Snape, J.; Van Den Berg, J.; Guy, S.J.; Manocha, D. Smooth and collision-free navigation for multiple robots under differential-drive constraints. In 2010 IEEE/RSJ International Conference on Intelligent Robots and Systems; IEEE: Piscataway, NJ, USA, 2010; pp. 4584–4589. [Google Scholar]
- Alonso-Mora, J.; Breitenmoser, A.; Rufli, M.; Beardsley, P.; Siegwart, R. Optimal reciprocal collision avoidance for multiple non-holonomic robots. In Distributed Autonomous Robotic Systems: The 10th International Symposium; Springer: Berlin/Heidelberg, Germany, 2013; pp. 203–216. [Google Scholar]
- Alonso-Mora, J.; Breitenmoser, A.; Beardsley, P.; Siegwart, R. Reciprocal collision avoidance for multiple car-like robots. In 2012 IEEE International Conference on Robotics and Automation; IEEE: Piscataway, NJ, USA, 2012; pp. 360–366. [Google Scholar]
- Everett, M.; Chen, Y.F.; How, J.P. Motion planning among dynamic, decision-making agents with deep reinforcement learning. In 2018 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS); IEEE: Piscataway, NJ, USA, 2018; pp. 3052–3059. [Google Scholar]
- Chen, C.; Liu, Y.; Kreiss, S.; Alahi, A. Crowd-robot interaction: Crowd-aware robot navigation with attention-based deep reinforcement learning. In 2019 International Conference on Robotics and Automation (ICRA); IEEE: Piscataway, NJ, USA, 2019; pp. 6015–6022. [Google Scholar]
- Chen, C.; Hu, S.; Nikdel, P.; Mori, G.; Savva, M. Relational graph learning for crowd navigation. In 2020 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS); IEEE: Piscataway, NJ, USA, 2020; pp. 10007–10013. [Google Scholar]
- Fan, T.; Long, P.; Liu, W.; Pan, J. Distributed multi-robot collision avoidance via deep reinforcement learning for navigation in complex scenarios. Int. J. Robot. Res. 2020, 39, 856–892. [Google Scholar] [CrossRef] [Scilit]
- Qin, J.; Qin, J.; Qiu, J.; Liu, Q.; Li, M.; Ma, Q. SRL-ORCA: A socially aware multi-agent mapless navigation algorithm in complex dynamic scenes. IEEE Robot. Autom. Lett. 2023, 9, 143–150. [Google Scholar] [CrossRef] [Scilit]
- Xie, Z.; Dames, P. Drl-vo: Learning to navigate through crowded dynamic scenes using velocity obstacles. IEEE Trans. Robot. 2023, 39, 2700–2719. [Google Scholar] [CrossRef] [Scilit]
- Martinez-Baselga, D.; Riazuelo, L.; Montano, L. RUMOR: Reinforcement learning for understanding a model of the real world for navigation in dynamic environments. Robot. Auton. Syst. 2025, 191, 105020. [Google Scholar] [CrossRef] [Scilit]
- Ames, A.D.; Coogan, S.; Egerstedt, M.; Notomista, G.; Sreenath, K.; Tabuada, P. Control barrier functions: Theory and applications. In 2019 18th European Control Conference (ECC); IEEE: Piscataway, NJ, USA, 2019; pp. 3420–3431. [Google Scholar]
- Tayal, M.; Singh, R.; Keshavan, J.; Kolathaya, S. Control barrier functions in dynamic uavs for kinematic obstacle avoidance: A collision cone approach. In 2024 American Control Conference (ACC); IEEE: Piscataway, NJ, USA, 2024; pp. 3722–3727. [Google Scholar]
- Tayal, M.; Kolathaya, S. Polygonal Cone Control Barrier Functions (PolyC2BF) for safe navigation in cluttered environments. In 2024 European Control Conference (ECC); IEEE: Piscataway, NJ, USA, 2024; pp. 2212–2217. [Google Scholar]
- Roncero, A.S.; Muchacho, R.I.C.; Ögren, P. Multi-agent obstacle avoidance using velocity obstacles and control barrier functions. In 2025 IEEE International Conference on Robotics and Automation (ICRA); IEEE: Piscataway, NJ, USA, 2025; pp. 6638–6644. [Google Scholar]
- Huang, J.; Zeng, J.; Chi, X.; Sreenath, K.; Liu, Z.; Su, H. Dynamic collision avoidance using velocity obstacle-based control barrier functions. IEEE Trans. Control Syst. Technol. 2025, 33, 1601–1615. [Google Scholar] [CrossRef] [Scilit]
- Long, K.; Dhiman, V.; Leok, M.; Cortés, J.; Atanasov, N. Safe control synthesis with uncertain dynamics and constraints. IEEE Robot. Autom. Lett. 2022, 7, 7295–7302. [Google Scholar] [CrossRef] [Scilit]
- Brito, B.; Floor, B.; Ferranti, L.; Alonso-Mora, J. Model predictive contouring control for collision avoidance in unstructured dynamic environments. IEEE Robot. Autom. Lett. 2019, 4, 4459–4466. [Google Scholar] [CrossRef]
- Adajania, V.K.; Sharma, A.; Gupta, A.; Masnavi, H.; Krishna, K.M.; Singh, A.K. Multi-modal model predictive control through batch non-holonomic trajectory optimization: Application to highway driving. IEEE Robot. Autom. Lett. 2022, 7, 4220–4227. [Google Scholar] [CrossRef] [Scilit]
- Mavrogiannis, C.; Balasubramanian, K.; Poddar, S.; Gandra, A.; Srinivasa, S.S. Winding through: Crowd navigation via topological invariance. IEEE Robot. Autom. Lett. 2022, 8, 121–128. [Google Scholar] [CrossRef] [Scilit]
- Ren, K.; Ahn, H.; Kamgarpour, M. Chance-constrained trajectory planning with multimodal environmental uncertainty. IEEE Control Syst. Lett. 2022, 7, 13–18. [Google Scholar] [CrossRef] [Scilit]
- de Groot, O.; Ferranti, L.; Gavrila, D.M.; Alonso-Mora, J. Scenario-based motion planning with bounded probability of collision. Int. J. Robot. Res. 2025, 44, 1507–1525. [Google Scholar] [CrossRef] [Scilit]
- de Groot, O.; Ferranti, L.; Gavrila, D.; Alonso-Mora, J. Globally Guided Trajectory Planning in Dynamic Environments. In 2023 IEEE International Conference on Robotics and Automation (ICRA); IEEE: Piscataway, NJ, USA, 2023; pp. 10118–10124. [Google Scholar]
- de Groot, O.; Ferranti, L.; Gavrila, D.M.; Alonso-Mora, J. Topology-Driven Parallel Trajectory Optimization in Dynamic Environments. IEEE Trans. Robot. 2025, 41, 110–126. [Google Scholar] [CrossRef] [Scilit]
- Alonso-Mora, J.; Gohl, P.; Watson, S.; Siegwart, R.; Beardsley, P. Shared control of autonomous vehicles based on velocity space optimization. In 2014 IEEE International Conference on Robotics and Automation (ICRA); IEEE: Piscataway, NJ, USA, 2014; pp. 1639–1645. [Google Scholar]





| Scenario | # Agents | % Coop. | [rad/s] |
|---|---|---|---|
| E1 | 20 | 100% | 2.5 |
| E2 | 20 | 50% | 2.5 |
| E3 | 20 | 100% | 0.5 |
| E4 | 20 | 50% | 0.5 |
| E5 | 10 | 100% | 2.5 |
| Scenario | Method | Coll. Rate [%] | Mean Time [s] |
|---|---|---|---|
| E1 | ORCA | 17.6 | 3.25 |
| NH-ORCA | 0.0 | 5.03 | |
| AVOCADO | 13.2 | 3.25 | |
| DD-AVOCADO | 0.0 | 4.92 | |
| E2 | ORCA | 28.7 | 4.30 |
| NH-ORCA | 6.1 | 5.37 | |
| AVOCADO | 27.6 | 4.24 | |
| DD-AVOCADO | 2.4 | 5.30 | |
| E3 | ORCA | 71.0 | 3.93 |
| NH-ORCA | 0.0 | 23.57 | |
| AVOCADO | 66.8 | 4.13 | |
| DD-AVOCADO | 0.0 | 22.48 | |
| E4 | ORCA | 91.7 | 4.74 |
| NH-ORCA | 31.2 | 12.38 | |
| AVOCADO | 89.1 | 4.71 | |
| DD-AVOCADO | 25.6 | 11.76 | |
| E5 | ORCA | 12.8 | 7.17 |
| NH-ORCA | 0.0 | 9.85 | |
| AVOCADO | 10.1 | 8.26 | |
| DD-AVOCADO | 0.0 | 8.96 |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Martinez-Baselga, D.; Lanaspa, D.; Riazuelo, L.; Montano, L. Adaptive Optimal Collision Avoidance of Dynamic Agents for Differential-Drive Robots. Robotics 2026, 15, 72. https://doi.org/10.3390/robotics15040072
Martinez-Baselga D, Lanaspa D, Riazuelo L, Montano L. Adaptive Optimal Collision Avoidance of Dynamic Agents for Differential-Drive Robots. Robotics. 2026; 15(4):72. https://doi.org/10.3390/robotics15040072
Chicago/Turabian StyleMartinez-Baselga, Diego, Diego Lanaspa, Luis Riazuelo, and Luis Montano. 2026. "Adaptive Optimal Collision Avoidance of Dynamic Agents for Differential-Drive Robots" Robotics 15, no. 4: 72. https://doi.org/10.3390/robotics15040072
APA StyleMartinez-Baselga, D., Lanaspa, D., Riazuelo, L., & Montano, L. (2026). Adaptive Optimal Collision Avoidance of Dynamic Agents for Differential-Drive Robots. Robotics, 15(4), 72. https://doi.org/10.3390/robotics15040072